Takeoff
Movement.takeoff()
Returns
NothingDescription
Tells the robot to takeoff using project's Movement Panel skill. The Movement Panel skill must have takeoff capability.
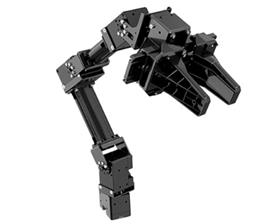 Robotis Openmanipulatorx
— Inverse kinematics for Robotis OpenManipulatorX: compute joint angles and MoveTo 3D (cm) positions, supports camera-to-CM mapping for pick-and-place.
Try it →
Movement.takeoff()
Tells the robot to takeoff using project's Movement Panel skill. The Movement Panel skill must have takeoff capability.