Release
Servo.release(port, [ezbIndex])
Parameters
| port | Servo port to release. |
| ezbIndex (optional) | Board index of the EZB to use. |
Returns
NothingDescription
Stops the servo at the specified port from holding its position.
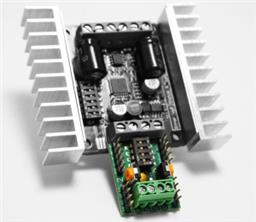 Sabertooth Kangaroo
— Movement panel enabling Kangaroo & Sabertooth encoder-based speed/velocity control, UART/PC serial options, tuning and encoder setup.
Try it →
Servo.release(port, [ezbIndex])
| port | Servo port to release. |
| ezbIndex (optional) | Board index of the EZB to use. |
Stops the servo at the specified port from holding its position.