Docs
ARCx Robot Skills
Overview
Robot Skills for Synthiam ARCx
Discover how Synthiam ARCx Robot Skills give your robot advanced capabilities, including vision,
speech, servo control, hardware control, and more. ARCx runs on Windows, Linux, and Raspberry Pi,
and its Robot Skills load and unload while the robot keeps running. Browse skill categories to find
the right behaviors for your ARCx project.
ARCx robot apps are built from Robot Skills. Each skill is an independent plug-in module that
represents a specific behavior or capability for your robot, such as a camera, speech,
a controller, or a sensor.
Add and remove while the robot runs. Skills load and unload without restarting ARCx.Skills declare their platforms. Each skill lists the operating systems it supports, so it only appears where it can run.Skills talk to each other. Control commands let skills and scripts work together, and can return values.
Add Robot Skills to your ARCx project from the + Skills menu to quickly
integrate powerful features without writing low-level code. Looking for skills for the original
Windows ARC? See the ARC Robot Skills overview .
ARCx Robot Skill Categories
ADC ARCx Robot Skills
The ADC (Analog-to-Digital Converter) category in Synthiam ARC provides the capability to read analog signals from sensors, converting real-world signals into digital data. This is essential for interfacing with analog sensors and devices, allowing robots to gather precise data from the physical environment.
Monitor EZB ADC ports with per-port schedules, scaled values, graphs/meters, alarms, and global variables for scripts and UI.
Artificial Intelligence ARCx Robot Skills
The Artificial Intelligence category in Synthiam ARC empowers robots with advanced cognitive abilities. Through integration with AI services, robots can recognize objects, understand speech, and make intelligent decisions. This skill category opens up a realm of possibilities for creating smart and responsive robotic systems.
Offline AIML chatbot for ARCx with built-in editor, memory, speech, scripts, quick replies, and robot control commands
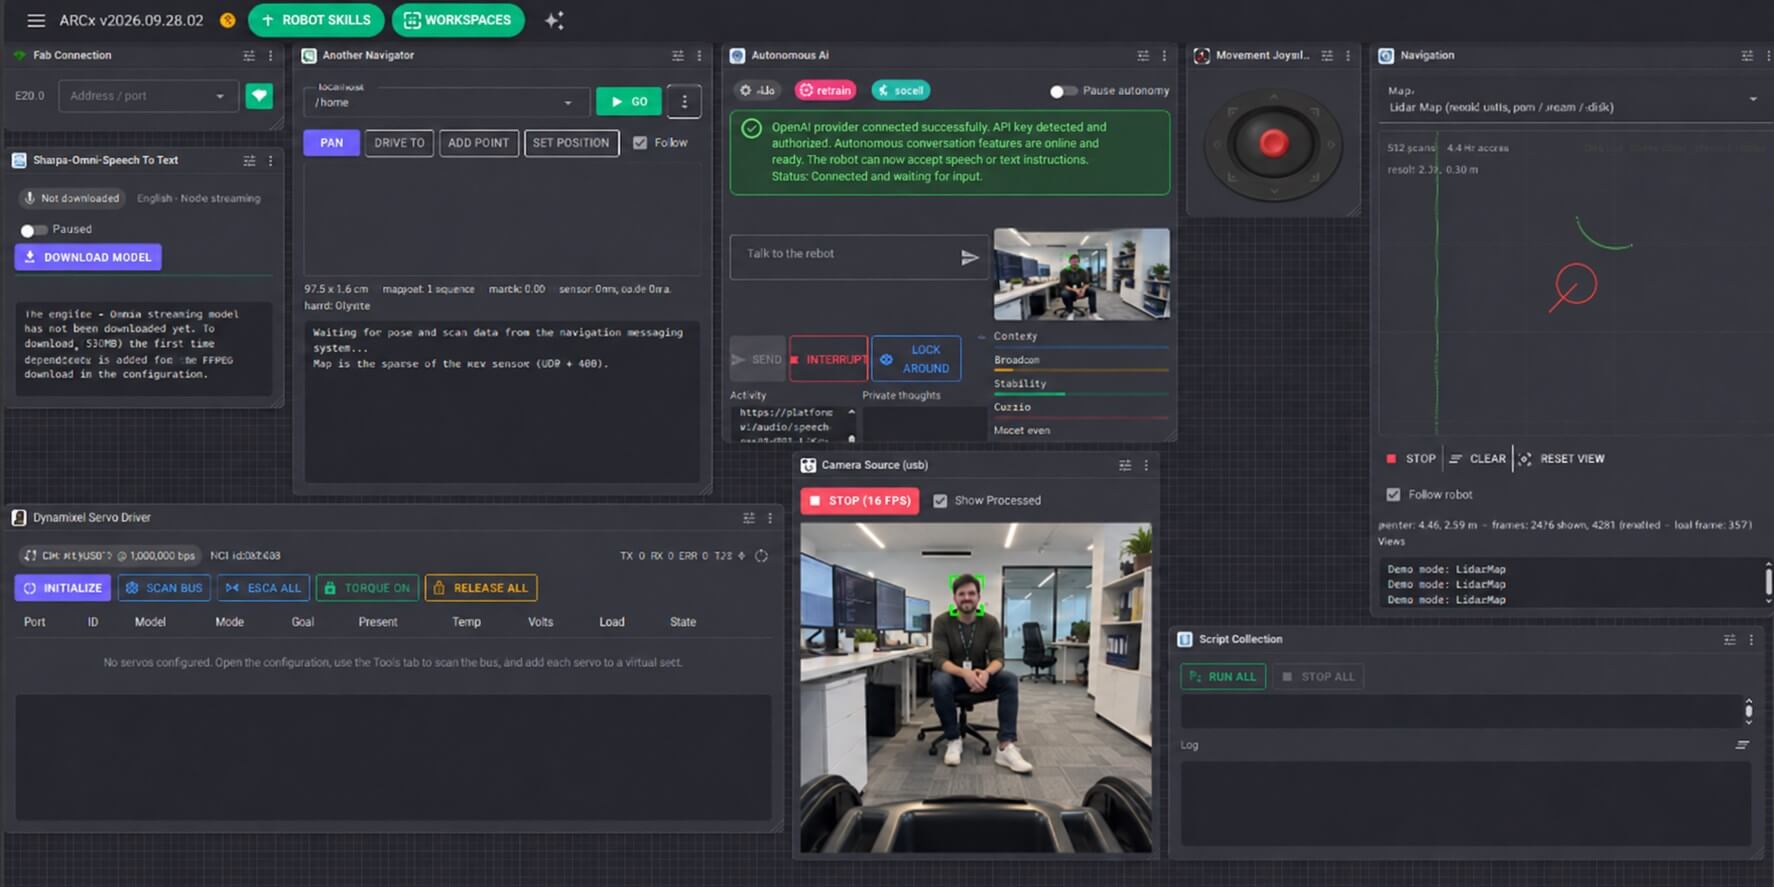
Autonomous AI robot brain for vision, speech, driving, scripts, memory, goals, and tool use with any LLM provider.
OpenAI/Gemini/Groq chatbot for robots with memory, vision, speech, and JavaScript actions via OpenAI API-compatible models
Camera
Artificial Intelligence
Camera
Analyzes camera images for eight emotions, logs scores, triggers scripts, and can speak or auto-detect mood changes.
Cloud vision for scene descriptions, OCR, object boxes, tags, adult/racy scores, scripts, auto mode, and MCP tools for ARCx
AI robot skill with Hugging Face chat, vision, object finding, watching, and Whisper speech recognition for ARCx
Speech-to-text with Whisper for ARC: transcribes phrases in many languages via OpenAI, Groq, or local OpenAI-compatible servers.
Audio
Artificial Intelligence
Audio
Offline English sentiment analysis with mood tracking, speech/chat scoring, scripts, variables, and AI tools for ARCx robots
Audio ARCx Robot Skills
The Audio category in Synthiam ARC enables robots to interact with their surroundings through sound. It includes features such as speech synthesis, audio playback, and voice recognition. This skill set is crucial for creating robots that can communicate effectively using auditory cues.
Azure neural text-to-speech for ARCx scripts and skills, with multilingual voices, SSML support, and EZB audio output.
Offline AIML chatbot for ARCx with built-in editor, memory, speech, scripts, quick replies, and robot control commands
Control Alexa devices from ARC: speak, announce, run routines, ask questions, play media, and trigger robot scripts from voice history.
Azure-powered speech recognition via Synthiam account, with wake word support, phrase capture, and ARCx scripting/custom UI integration.
Azure-powered multilingual speech-to-text for ARCx with language detection, wake words, phrase recognition, and script listening.
English-only cloud TTS for ARCx using classic Windows voices; speaks project audio on PC or EZB speaker with one-login setup
Voice-driven nested menus for robots: ask questions, listen for choices, run scripts, and support clickable or tap-to-select options.
Listens to microphone pitch, publishes frequency and note, moves servos, and triggers scripts from detected sound bands
AI robot skill with Hugging Face chat, vision, object finding, watching, and Whisper speech recognition for ARCx
Records microphone audio into named slots and plays it through an EZB speaker, with recordings stored in the project.
Turns MIDI controllers into robot controls for servos, movement, variables, scripts, lighting, and synth output with layers and feedback
Offline F5-TTS voice cloning for ARCx: train voices, speak replies instantly, and save MP3/WAV with no cloud or per-sentence cost
Speech-to-text with Whisper for ARC: transcribes phrases in many languages via OpenAI, Groq, or local OpenAI-compatible servers.
Audio
Artificial Intelligence
Audio
Offline speech-to-text engine for ARCx using sherpa-onnx models; runs locally on Windows, Linux, Raspberry Pi, and Mac with no internet after download
Import WAV/MP3 audio, store it in the project, and trigger robot scripts at exact timeline markers for synced sound and motion.
Voice command phrase recognition that triggers scripts via your project’s speech-to-text engine, with confidence filtering and wake-word support.
Moves mouth or jaw servos to sync with TTS speech, using audio level or text timing for lifelike talking heads.
Offline English sentiment analysis with mood tracking, speech/chat scoring, scripts, variables, and AI tools for ARCx robots
Detects human speech from microphone energy, ignoring noise and robot speech, to trigger scripts or wake speech recognition.
Local Windows text-to-speech and speech recognition for ARCx: speak, listen, wake-word detect, and run offline without internet or accounts.
Camera ARCx Robot Skills
The Camera category in Synthiam ARC facilitates visual perception for robots. With camera-related functionalities, robots can capture images, process visual data, and perform tasks such as object recognition and tracking. This category is fundamental for developing vision-based robotic applications.
Camera-guided docking to a printed glyph with charging confirmation, undocking, retries, and Movement Manager support
Camera-based robot pose tracking for ARCx with perspective calibration, floor mapping, and NMS navigation without encoders, lidar, or SLAM.
Save JPEG or PNG snapshots from any running camera source on demand, in bursts, or on a timer for time-lapse capture.
Publishes an EZB camera as an ARCx video source for tracking, recording, and AI skills over the network, with processed or raw view.
Publishes a camera feed as a named ARCx video source for face tracking, object tracking, recording, and autonomous AI.
OpenAI/Gemini/Groq chatbot for robots with memory, vision, speech, and JavaScript actions via OpenAI API-compatible models
Camera
Artificial Intelligence
Camera
Analyzes camera images for eight emotions, logs scores, triggers scripts, and can speak or auto-detect mood changes.
Cloud vision for scene descriptions, OCR, object boxes, tags, adult/racy scores, scripts, auto mode, and MCP tools for ARCx
Detects taught colors in camera video, reporting position, size, shape, rotation and distance with per-color scripts and tracking support.
Control DJI/Ryze Tello drones from ARCx with live video, telemetry, mission pads, movement scripts, HUD, and AI tools.
Detects faces in camera video, marks them, and tracks the largest face for servo tracking and presence detection
Detect printed glyphs, identify rotation, distance and position, and trigger scripts for each marker in view.
AI robot skill with Hugging Face chat, vision, object finding, watching, and Whisper speech recognition for ARCx
Intel RealSense depth camera skill for ARCx navigation, video, measured detections, tilt sensing, recordings, and point clouds.
Tracks robot position and heading with Intel RealSense cameras, sending data to ARCx navigation, scripts, variables, video, and maps.
Turn your body into a robot controller with Kinect or any camera, tracking gestures, joints, scripts, and servo mappings in 3D.
Servo
Camera
Remote Control
Servo
Uses Kinect v1 as a depth sensor for obstacle scans, floor-drop detection, vision range measurement, tilt/LED control, and simulated testing across platforms.
ARCx control for Mebo 2 Wi‑Fi robot: drive wheels, move arm/claw, stream camera, lights, battery, speak, and use AI tools-no cloud needed
Train textured objects from camera or images, detect them in video, run scripts, publish position, and draw bounding boxes.
Build custom OpenCV pipelines to detect colors, shapes, edges, and contours with live step-by-step tuning in ARCx.
Orbbec 3D camera skill for ARCx: obstacle scans, video, depth, IMU tilt, detections distance, recordings, point clouds, multi-camera support
Turns a Stereolabs ZED camera into GPU-free depth, obstacle scans, video, IMU and AI-ready 3D sensing for ARC on Windows, Linux and macOS.
Structure Sensor depth, obstacle scanning, 3D scanning, recording, playback, and paired-color vision for robots via OpenNI2
Plays video files as a virtual camera in ARCx for vision skills, with playlists, repeat modes, embedded files, and scripting support
Real-time video compositor for camera overlays, text, graphics, effects, meters, templates, and scripted transitions.
Records raw or processed camera video to .mkv files with overlays, for demos, evidence, and reviewing tracking behavior.
Play RTSP, MJPEG, snapshots, HLS, video files and web streams as an ARCx camera for vision skills, with auto reconnect and web page resolution.
Tracks detections from one camera to drive servos, movement, scripts, variables, and commands for faces, glyphs, objects, and colors.
Teach-and-repeat navigation with one camera: train waypoints and routes, then drive to places by visual matching.
Zivid 3D camera skill for ARCx: captures aligned color/depth snapshots, detects pick points, measures objects, exports clouds, and drives arm picks.
Camera
Camera
Infrared Distance
Navigation
Communication ARCx Robot Skills
The Communication category in Synthiam ARC focuses on enabling robots to interact and exchange information with other devices. This includes communication protocols, data sharing, and network connectivity. It is crucial for building robots that can collaborate and communicate in various environments.
Control Alexa devices from ARC: speak, announce, run routines, ask questions, play media, and trigger robot scripts from voice history.
Connects ARCx to EZ-B boards over serial, network, or TCP listener, with multi-board control, connection scripts, and project audio routing
Connect ARCx to Modbus, OPC UA, EtherNet/IP or Siemens S7 PLCs with shared tags, events, scripts, UI widgets and simulator support
MQTT broker for ARCx with robot bridge, topics, triggers, retained messages, TLS/WebSockets, security, and scripting control
MQTT client for ARCx: connect to brokers, subscribe/publish topics, bridge robot data to Home Assistant, and enable remote control.
Send Pushover push alerts from your robot to phone, smartwatch or desktop with images, priorities, emergencies, and variable alerts.
Bridge ARCx and ROS 2 via rosbridge: bind topics, publish Robot Bus data, and expose ARCx services without ROS installed.
Serial terminal for ARC and EZ-B UARTs with macros, triggers, scripts, logs, and AI tools for serial devices
Connects ARCx to Viam viam-server, auto-mapping robot resources to movement, servos, cameras, sensors, and Robot Bus data.
Digital ARCx Robot Skills
The Digital category in Synthiam ARC deals with digital signal processing and manipulation. It includes functions for working with digital sensors, logic operations, and data processing. This skill set is essential for handling digital information in robotic applications.
Controls two BLDC motor controllers for ARC movement, with ramping, brakes, wiring test, safety stops, and multi-EZB support.
Digital
Digital
Movement Panels
PWM
Monitors EZB digital ports, debounces inputs, publishes globals, logs state, counts presses, and runs scripts on changes
HC-SR04 ultrasonic distance sensor skill with filtering, alarms, obstacle guard, navigation support, and shared distance variables
Display ARCx Robot Skills
The Display category in Synthiam ARC allows robots to present information visually. It includes features for controlling displays, showing images, and rendering graphical content. This skill set is valuable for creating robots that can convey information to users in a clear and engaging manner.
Live robot data charts with alarms, markers, hover stats, CSV/PNG export, and 10 chart types for variables, sensors, scripts, and more
Graphs
Display
Graphs
Scripting
Design touch-screen robot control panels with buttons, sliders, gauges, joysticks, live variables, scripts, and Wi-Fi/USB display support.
Display
Display
Remote Control
Servo
3D virtual robot simulator wired to ARCx EZBs with servo, sensor, camera and lidar support for testing and training without hardware
Display web pages on robot screens with window, fullscreen, or kiosk modes and two-way page messaging for dashboards, calls, and kiosks.
Examples ARCx Robot Skills
Example robot skills with sourcecode to see how they are created as reference when creating your own.
ARCx testing scaffold showcasing skill lifecycle, config JSON, control commands, UI, timer, and static assets for developer reference
Demo skill showing live graphics in ARCx UCSkillCanvas: lidar map, audio meter, graph, and paint, all simulated with no hardware.
General ARCx Robot Skills
The General category in Synthiam ARC encompasses a wide range of general-purpose robot skills. It includes versatile functionalities that can be applied across different robotic applications, providing a foundation for building custom behaviors and features.
Connect ARCx to Modbus, OPC UA, EtherNet/IP or Siemens S7 PLCs with shared tags, events, scripts, UI widgets and simulator support
Runs scripts on robot direction changes for lights, sounds, logs and actions without driving the motors
Send Pushover push alerts from your robot to phone, smartwatch or desktop with images, priorities, emergencies, and variable alerts.
Flexible script scheduler for timed, solar, cron, and one-time runs with conditions, history, and parallel execution
Monitor ARCx CPU, memory, threads, skills, devices and .NET health with alerts, history graphs, and AI-accessible diagnostics.
Serial terminal for ARC and EZ-B UARTs with macros, triggers, scripts, logs, and AI tools for serial devices
Graphs ARCx Robot Skills
The Graphs category in Synthiam ARC focuses on visualizing data through graphical representations. It includes tools for creating charts, graphs, and visual displays of information. This skill set is useful for presenting complex data in a comprehensible manner.
Monitor EZB ADC ports with per-port schedules, scaled values, graphs/meters, alarms, and global variables for scripts and UI.
Monitors EZB digital ports, debounces inputs, publishes globals, logs state, counts presses, and runs scripts on changes
Live robot data charts with alarms, markers, hover stats, CSV/PNG export, and 10 chart types for variables, sensors, scripts, and more
Graphs
Display
Graphs
Scripting
Listens to microphone pitch, publishes frequency and note, moves servos, and triggers scripts from detected sound bands
Reads an MPU6050 IMU on EZB, calculates orientation, shows 3D/horizon/graphs, publishes variables, and triggers tilt/shock/fall alarms
I2C
Graphs
I2C
Navigation
3D drawing for servos or robot arms: live trail, sketch pad, shapes, SVG import, recording, playback, and AI-assisted control
Monitor ARCx CPU, memory, threads, skills, devices and .NET health with alerts, history graphs, and AI-accessible diagnostics.
I2C ARCx Robot Skills
The I2C (Inter-Integrated Circuit) category in Synthiam ARC facilitates communication between devices using the I2C protocol. This skill set is crucial for connecting and interacting with a variety of sensors and peripherals in a robotics system.
Reads an MPU6050 IMU on EZB, calculates orientation, shows 3D/horizon/graphs, publishes variables, and triggers tilt/shock/fall alarms
I2C
Graphs
I2C
Navigation
Drives up to 16 servos per PCA9685 over I2C from ARC virtual ports with per-channel mapping, ramping, trim, and calibration.
Creates and plays named RGB eye animations on the EZ-Robot I2C module with 18 LEDs, fades, repeats, and script/AI triggers.
Infrared Distance ARCx Robot Skills
The Infrared Distance category in Synthiam ARC enables robots to measure distances using infrared sensors. This is essential for obstacle avoidance, navigation, and proximity sensing. Robots equipped with this capability can interact safely in dynamic environments.
Intel RealSense depth camera skill for ARCx navigation, video, measured detections, tilt sensing, recordings, and point clouds.
Uses Kinect v1 as a depth sensor for obstacle scans, floor-drop detection, vision range measurement, tilt/LED control, and simulated testing across platforms.
Orbbec 3D camera skill for ARCx: obstacle scans, video, depth, IMU tilt, detections distance, recordings, point clouds, multi-camera support
Turns a Stereolabs ZED camera into GPU-free depth, obstacle scans, video, IMU and AI-ready 3D sensing for ARC on Windows, Linux and macOS.
Structure Sensor depth, obstacle scanning, 3D scanning, recording, playback, and paired-color vision for robots via OpenNI2
Zivid 3D camera skill for ARCx: captures aligned color/depth snapshots, detects pick points, measures objects, exports clouds, and drives arm picks.
Camera
Camera
Infrared Distance
Navigation
Movement Panels ARCx Robot Skills
The Movement Panels category in Synthiam ARC focuses on controlling and managing the movement of robots. It includes features for controlling motors, wheels, and other actuators, allowing robots to navigate and move in a controlled manner. There can only be one movement panel per project.
Movement Panel Details
Animate servo poses into actions for walking, waving, standing or sitting; supports joystick movement and gait control for humanoids/hexapods.
Controls two BLDC motor controllers for ARC movement, with ramping, brakes, wiring test, safety stops, and multi-EZB support.
Digital
Digital
Movement Panels
PWM
Movement panel for two continuous rotation servos or ESCs, controlling robot drive from ARC movement skills, scripts, Wiimote, and ROS cmd_vel.
Script-driven movement panel for any robot, drone, or API, with custom directions, speed control, and safety stops
Control DJI/Ryze Tello drones from ARCx with live video, telemetry, mission pads, movement scripts, HUD, and AI tools.
Front-wheel steering car movement panel for RC cars, rovers and toy conversions with servo, ESC, motor and odometry support
Movement panel for dual H-bridge motor controllers, driving two motors with optional PWM speed control in ARCx.
Movement panel for iRobot robots: drive, read sensors, track position, run scripts, play tunes, and connect via serial, Wi-Fi, or ROS 2
ARCx control for Mebo 2 Wi‑Fi robot: drive wheels, move arm/claw, stream camera, lights, battery, speak, and use AI tools-no cloud needed
Control an OhmniLabs telepresence robot from ARCx: wheels, neck, battery, light ring, odometry, docking, and navigation support.
Tank-drive movement panel for Kangaroo x2/Sabertooth with encoder odometry, NMS position, and measured drive/turn commands.
Controls a robot with a Dimension Engineering Sabertooth motor driver, supporting tank steering, ramping, telemetry, failsafes, and multiple protocols
Segway-style self-balancing robot control with live tuning, auto-tune, EEPROM saving, and ARCx drive/status support for Arduino or ESP32.
Connects ARCx to Viam viam-server, auto-mapping robot resources to movement, servos, cameras, sensors, and Robot Bus data.
Navigation ARCx Robot Skills
The Navigation category in Synthiam ARC is dedicated to enabling robots to navigate and move autonomously. It includes functionalities such as path planning, obstacle avoidance, and localization. This skill set is crucial for developing robots capable of exploring and navigating complex environments.
Sensor-based SLAM navigation: builds maps, plans routes to waypoints, and drives using positioning, distance, and movement skills.
Camera-guided docking to a printed glyph with charging confirmation, undocking, retries, and Movement Manager support
Camera-based robot pose tracking for ARCx with perspective calibration, floor mapping, and NMS navigation without encoders, lidar, or SLAM.
USB lidar skill for Hitachi-LG LDS-01: scans to NMS, globals, obstacle zones, and live view for navigation.
Intel RealSense depth camera skill for ARCx navigation, video, measured detections, tilt sensing, recordings, and point clouds.
Tracks robot position and heading with Intel RealSense cameras, sending data to ARCx navigation, scripts, variables, video, and maps.
Uses Kinect v1 as a depth sensor for obstacle scans, floor-drop detection, vision range measurement, tilt/LED control, and simulated testing across platforms.
Reads an MPU6050 IMU on EZB, calculates orientation, shows 3D/horizon/graphs, publishes variables, and triggers tilt/shock/fall alarms
I2C
Graphs
I2C
Navigation
Queries NMS scan data for nearest obstacles, clear paths, open directions, zones, and pose without driving or mapping.
Orbbec 3D camera skill for ARCx: obstacle scans, video, depth, IMU tilt, detections distance, recordings, point clouds, multi-camera support
Sweeping ultrasonic radar with live display, obstacle avoidance, clearest-direction tracking, NMS output, and scriptable obstacle zones
HC-SR04 ultrasonic distance sensor skill with filtering, alarms, obstacle guard, navigation support, and shared distance variables
Slamtec RPLidar scanner integration for NMS, global variables, obstacle zones, and live scan view across USB, UART, or network.
Turns a Stereolabs ZED camera into GPU-free depth, obstacle scans, video, IMU and AI-ready 3D sensing for ARC on Windows, Linux and macOS.
Structure Sensor depth, obstacle scanning, 3D scanning, recording, playback, and paired-color vision for robots via OpenNI2
Teach-and-repeat navigation with one camera: train waypoints and routes, then drive to places by visual matching.
Zivid 3D camera skill for ARCx: captures aligned color/depth snapshots, detects pick points, measures objects, exports clouds, and drives arm picks.
Camera
Camera
Infrared Distance
Navigation
PWM ARCx Robot Skills
The PWM (Pulse Width Modulation) category in Synthiam ARC facilitates precise control of actuators such as motors and servos by adjusting the duty cycle of the signal. This skill set is crucial for achieving fine-grained control over the movement and position of robotic components.
Controls two BLDC motor controllers for ARC movement, with ramping, brakes, wiring test, safety stops, and multi-EZB support.
Digital
Digital
Movement Panels
PWM
Front-wheel steering car movement panel for RC cars, rovers and toy conversions with servo, ESC, motor and odometry support
Control an EZB digital port PWM duty cycle with a slider, buttons, and script commands for motors, lights, and fans.
Remote Control ARCx Robot Skills
The Remote Control category in Synthiam ARC enables robots to be controlled remotely by users. It includes functionalities for remote operation, telepresence, and remote monitoring. This skill set is valuable for scenarios where direct user control or observation is required.
Control Alexa devices from ARC: speak, announce, run routines, ask questions, play media, and trigger robot scripts from voice history.
Control DJI/Ryze Tello drones from ARCx with live video, telemetry, mission pads, movement scripts, HUD, and AI tools.
Remote robot control and telepresence from any browser, with video, audio, servos, scripts, and access-list permissions.
Cross-platform controller skill for driving robots, steering servos, flying drones, and running scripts with USB or Bluetooth gamepads/joysticks.
Browser-based keyboard robot control with remappable keys for driving, servo control, speed changes, scripts, and safe deadman stopping.
Turn your body into a robot controller with Kinect or any camera, tracking gestures, joints, scripts, and servo mappings in 3D.
Servo
Camera
Remote Control
Servo
Meta Quest teleoperation for ARCx: stereo video, head-tracked neck, 3D arm control, hand/finger tracking, driving, buttons, safety, haptics
Turns MIDI controllers into robot controls for servos, movement, variables, scripts, lighting, and synth output with layers and feedback
On-screen joystick for driving any ARC movement panel with mouse or touch; speed scales with drag distance and can stop on release.
MQTT broker for ARCx with robot bridge, topics, triggers, retained messages, TLS/WebSockets, security, and scripting control
MQTT client for ARCx: connect to brokers, subscribe/publish topics, bridge robot data to Home Assistant, and enable remote control.
Design touch-screen robot control panels with buttons, sliders, gauges, joysticks, live variables, scripts, and Wi-Fi/USB display support.
Display
Display
Remote Control
Servo
Control robots with a Wii Remote: D-Pad drives movement, buttons run scripts, and tilt can position servos. Windows, Linux, and macOS support.
Scripting ARCx Robot Skills
The Scripting category in Synthiam ARC empowers users to create custom scripts and behaviors for robots. It includes scripting languages and tools that allow users to define complex and customized robot actions, expanding the flexibility and capabilities of robotic systems. Here are the manuals for
JavaScript ,
Python ,
EZ-Script ,
Blockly , and
RoboScratch .
Script-driven movement panel for any robot, drone, or API, with custom directions, speed control, and safety stops
Live robot data charts with alarms, markers, hover stats, CSV/PNG export, and 10 chart types for variables, sensors, scripts, and more
Graphs
Display
Graphs
Scripting
Connect ARCx to Modbus, OPC UA, EtherNet/IP or Siemens S7 PLCs with shared tags, events, scripts, UI widgets and simulator support
Browser-based keyboard robot control with remappable keys for driving, servo control, speed changes, scripts, and safe deadman stopping.
Runs scripts on robot direction changes for lights, sounds, logs and actions without driving the motors
MQTT broker for ARCx with robot bridge, topics, triggers, retained messages, TLS/WebSockets, security, and scripting control
MQTT client for ARCx: connect to brokers, subscribe/publish topics, bridge robot data to Home Assistant, and enable remote control.
Build custom OpenCV pipelines to detect colors, shapes, edges, and contours with live step-by-step tuning in ARCx.
Runs real CPython in ARCx with VS Code-style editor, pip packages, ARCx API access, and bidirectional ControlCommand integration
Run JavaScript or Python scripts in ARCx to automate sequences, react to events, and control other skills via commands.
Manage multiple independent scripts in one robot skill window with grouped controls, shared logs, and control commands.
Flexible script scheduler for timed, solar, cron, and one-time runs with conditions, history, and parallel execution
Serial terminal for ARC and EZ-B UARTs with macros, triggers, scripts, logs, and AI tools for serial devices
Servo ARCx Robot Skills
The Servo category in Synthiam ARC focuses on controlling servo motors, allowing precise control over the rotational movement of robotic components. This skill set is essential for tasks requiring accurate and controlled motion in robotic applications.
Animate servo groups with frames and actions for waves, nods, gestures, and other robot motions.
Animate servo poses into actions for walking, waving, standing or sitting; supports joystick movement and gait control for humanoids/hexapods.
Turns an Arduino into an ARCx servo controller with virtual-port mapping, speed, release, sync, and position reads.
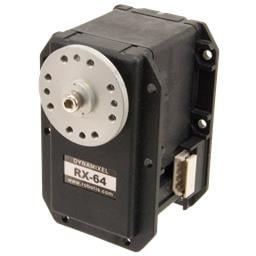
Drive Dynamixel smart servos from ARCx virtual ports over an EZB serial bus with sync writes, scans, telemetry, and mode control.
Drives Feetech SCS TTL serial bus servos from ARC virtual ports over EZB UART, digital port, or USB COM adapter.
Drives Feetech SM, STS, and SCS bus servos from ARCx virtual servo ports via EZB or COM port, with sync writes and telemetry.
Front-wheel steering car movement panel for RC cars, rovers and toy conversions with servo, ESC, motor and odometry support
Browser-based keyboard robot control with remappable keys for driving, servo control, speed changes, scripts, and safe deadman stopping.
Turn your body into a robot controller with Kinect or any camera, tracking gestures, joints, scripts, and servo mappings in 3D.
Servo
Camera
Remote Control
Servo
Publish robot arms as named kinematic chains and move tools by millimetre coordinates with inverse kinematics, linear moves, and saved poses.
Control LewanSoul/Hiwonder bus servos from ARCx virtual ports with UART, digital port, or BusLinker support and telemetry.
Controls Lynxmotion LSS/LSS-PRO smart servos from ARC virtual ports with UART, digital, or USB serial bus support.
Maps ARCx virtual servo ports to Pololu Maestro channels for servo control, with per-channel pulse, speed, accel, invert, and readback.
ARCx control for Mebo 2 Wi‑Fi robot: drive wheels, move arm/claw, stream camera, lights, battery, speak, and use AI tools-no cloud needed
Meta Quest teleoperation for ARCx: stereo video, head-tracked neck, 3D arm control, hand/finger tracking, driving, buttons, safety, haptics
Turns MIDI controllers into robot controls for servos, movement, variables, scripts, lighting, and synth output with layers and feedback
Drives up to 16 servos per PCA9685 over I2C from ARC virtual ports with per-channel mapping, ramping, trim, and calibration.
Sweeping ultrasonic radar with live display, obstacle avoidance, clearest-direction tracking, NMS output, and scriptable obstacle zones
Controls Kangaroo x2/Sabertooth motor axes as ARCx virtual servos with homing, limit switches, stalls, readback, and smooth motion.
Manual servo slider with center and release controls; follows external moves and respects safe position limits for one joint.
Record, edit, and loop servo motions with script points and audio tracks for precise robot playback and choreography
Puppeteer servos with a touch pad; smooth, record, loop, save poses, and control pan/tilt, eyes, necks, or shoulders.
3D drawing for servos or robot arms: live trail, sketch pad, shapes, SVG import, recording, playback, and AI-assisted control
Drives up to 32 servos on Lynxmotion SSC-32/SSC-32U from ARCx virtual ports with flexible mapping, speed, and pulse control
Turns stepper motors into ARCx servos with homing, position reads, speed control, and support for up to 127 motors across Arduino buses
Moves mouth or jaw servos to sync with TTS speech, using audio level or text timing for lifelike talking heads.
Design touch-screen robot control panels with buttons, sliders, gauges, joysticks, live variables, scripts, and Wi-Fi/USB display support.
Display
Display
Remote Control
Servo
Connects ARCx to Viam viam-server, auto-mapping robot resources to movement, servos, cameras, sensors, and Robot Bus data.
Ultrasonic Distance ARCx Robot Skills
The Ultrasonic Distance category in Synthiam ARC enables robots to measure distances using ultrasonic sensors. This is valuable for applications such as obstacle avoidance, object detection, and proximity sensing. Robots equipped with this capability can navigate and interact safely in various environments.
Sweeping ultrasonic radar with live display, obstacle avoidance, clearest-direction tracking, NMS output, and scriptable obstacle zones
HC-SR04 ultrasonic distance sensor skill with filtering, alarms, obstacle guard, navigation support, and shared distance variables
Virtual Reality ARCx Robot Skills
The Virtual Reality category in Synthiam ARC introduces immersive virtual experiences to robots. It includes features for integrating virtual reality technologies, allowing robots to interact with virtual environments and providing users with unique and engaging experiences.
Meta Quest teleoperation for ARCx: stereo video, head-tracked neck, 3D arm control, hand/finger tracking, driving, buttons, safety, haptics