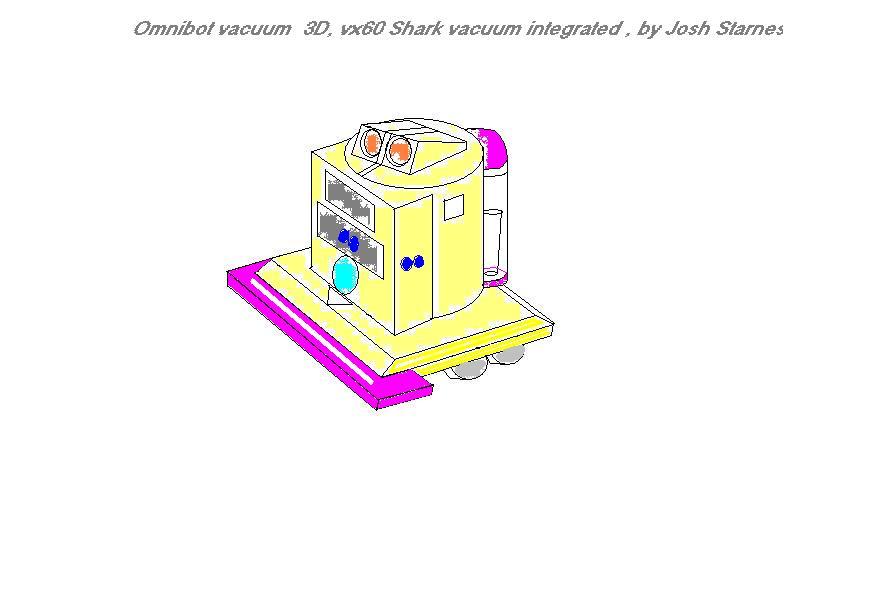
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.
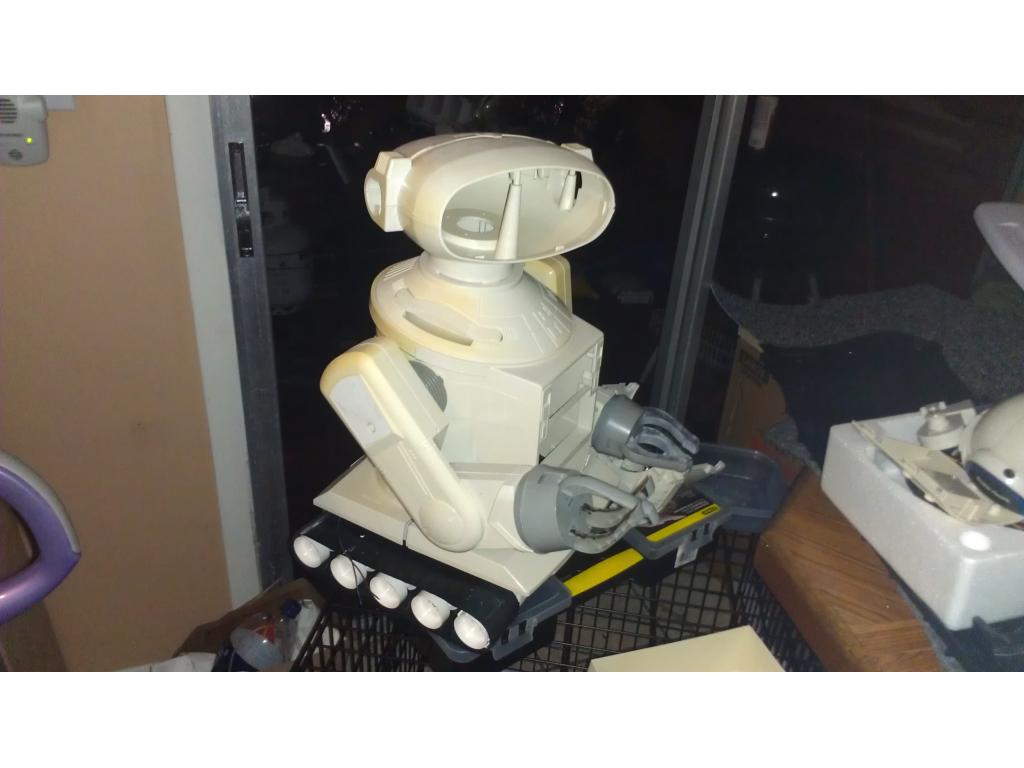
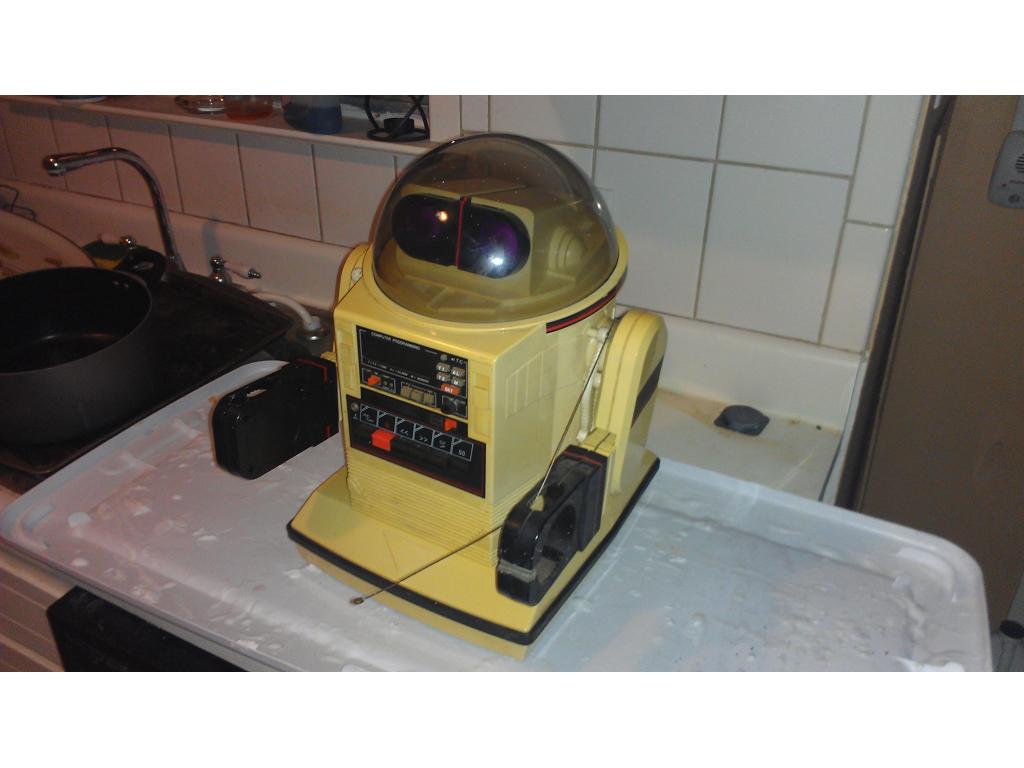
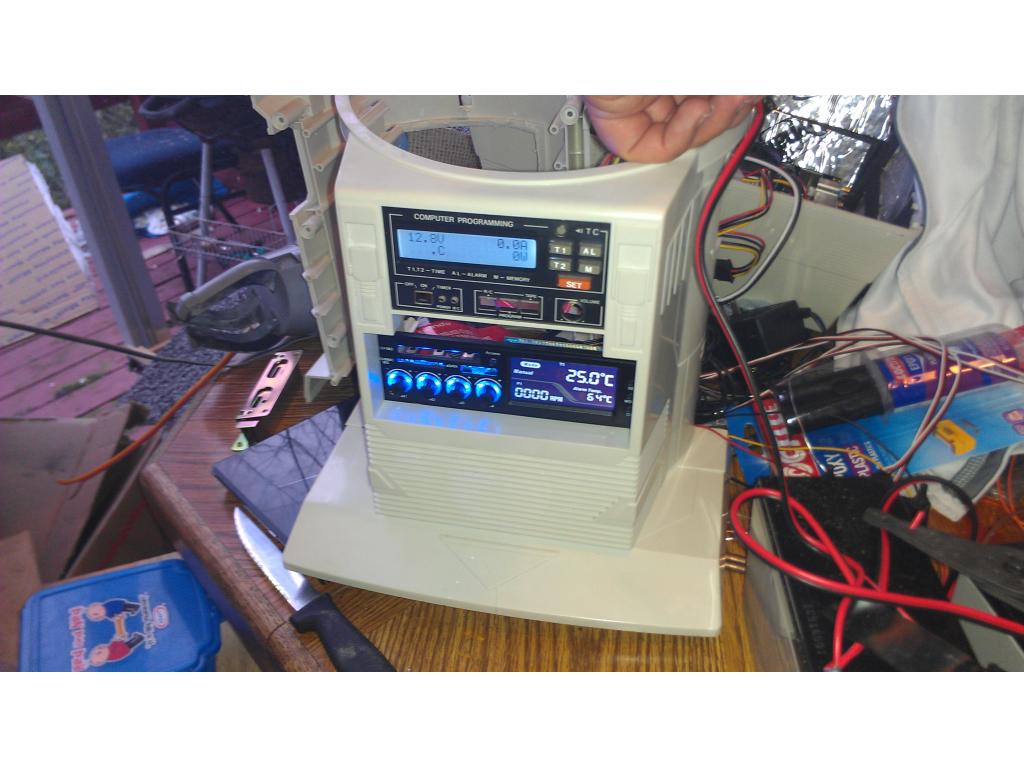
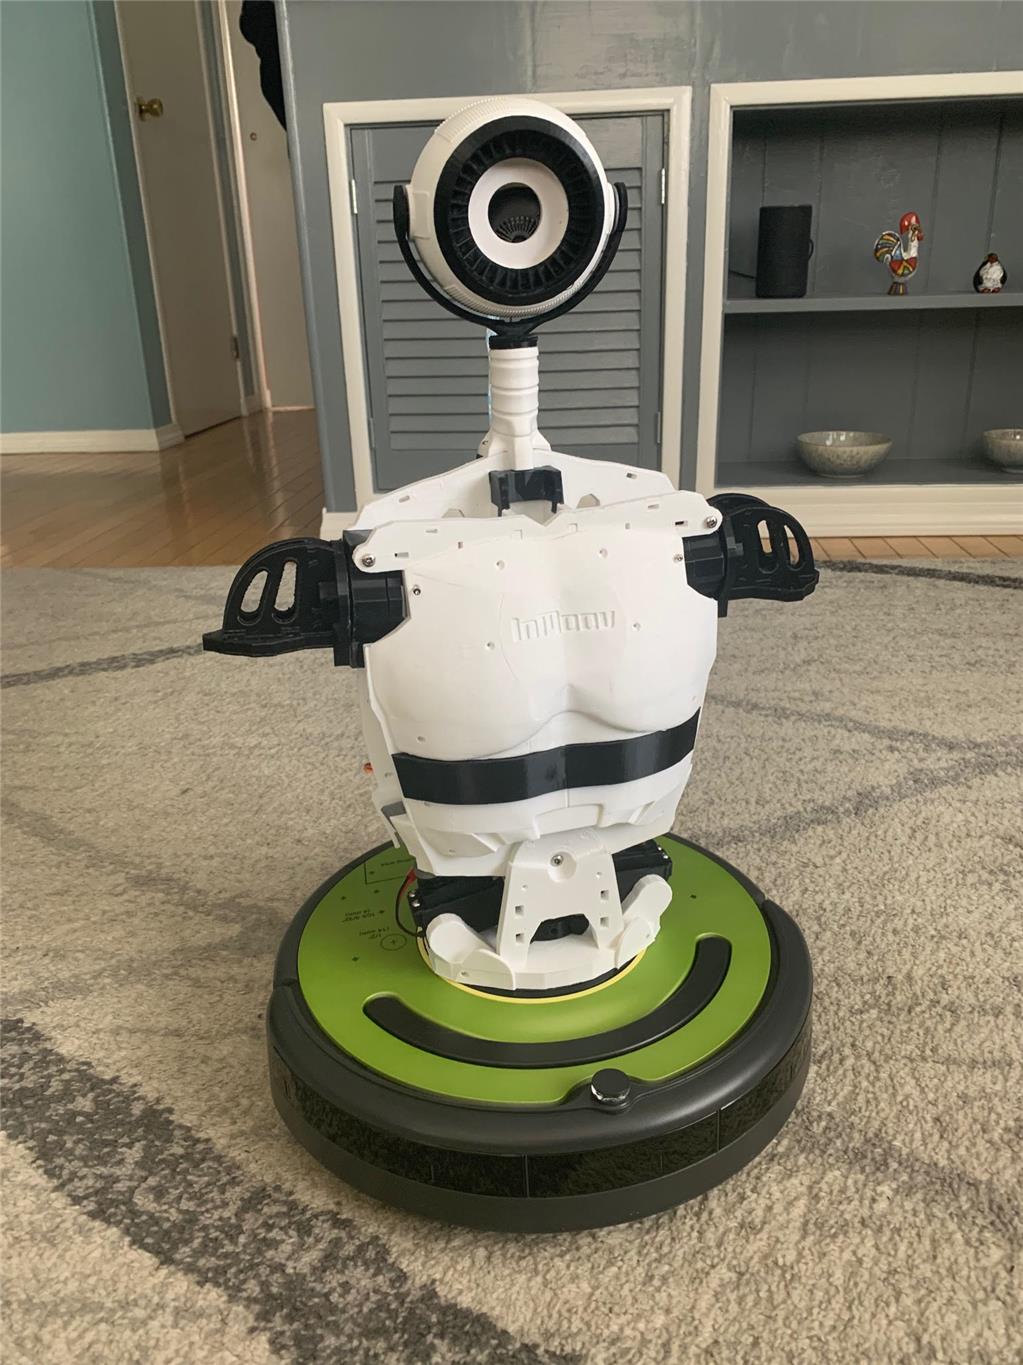
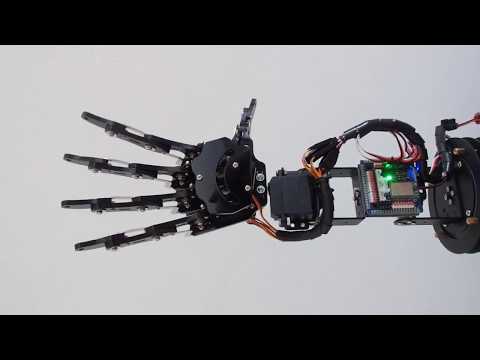

Making some good progress....
Ok I played fiberglass in the forearms. I have aluminum tubing slightly larger than the stand offs screw mounts. I was thinking of cutting this tubing and using it to reinforce these standoff by using.epoxy to glue them around these mounts.
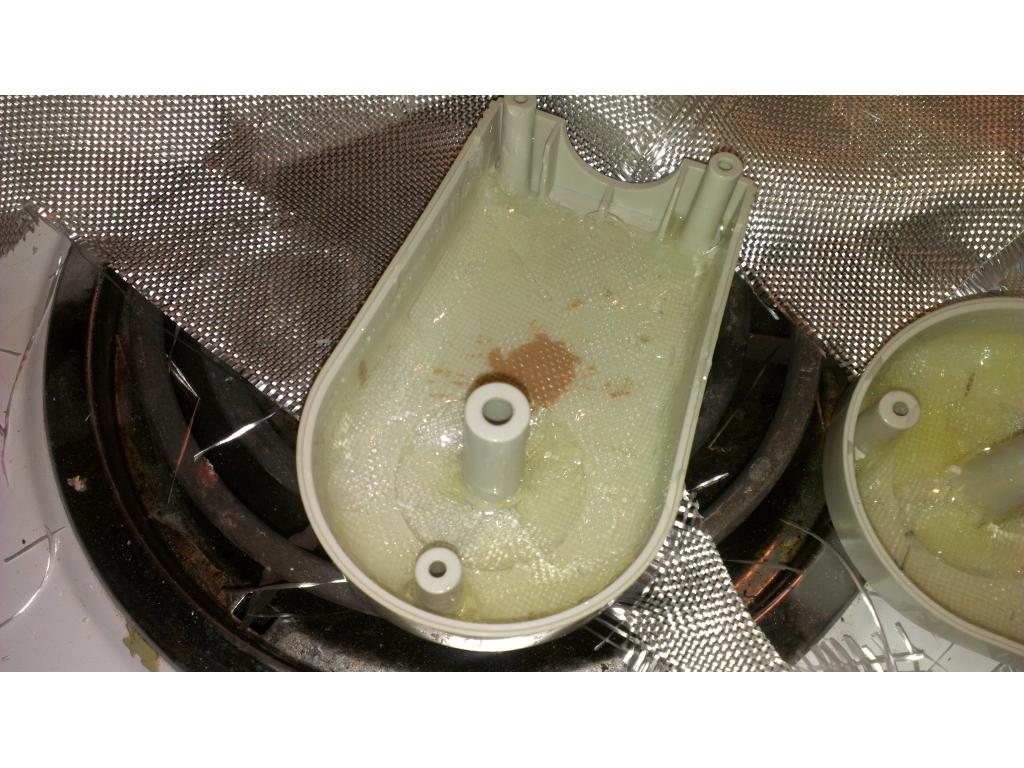
Ok so now the reinforcement of the forearms is pretty much done except those tubes to reinforce the mounting points. The elbow joint is probably not strong enough so I will probably epoxy in a bolt to use as a elbow mount/ pivot.How much weight does that add to it?
Yeah, he looks like he needs a diet. lol
It adds a couple ounces , if that, not much at all but once that layer of glass is in the flimsy part becomes strong and rigid. Take in mind I dremeled out about 10-20 percent of the insides to make room for a servo so its a very small difference. Thanks to the robotzone gearbox I will have over 2000 oz in of torque so I want to insure all the parts are durable BEFORE paint lol.
my arm design i am making a aluminium frame ,to hold the gears pots and servo's it will take the whole room of the arm,first it will easy to change any of the parts and second make it very strong both parts of the arm with have a custom frame for it with the gear ratio and special motor i will have over 2500 oz
josh your's look good,i see you are getting there
I didn't realize you drilled out for servos. Good more to add support. It is best to make him a little heavier vs his arm falling apart when he moves or carrying your beer. That would be terrible. He's gonna be so awesome.
@SFOY around monday or sooner will have my omnibot 2000 project up,first starting on the base using tracks,then after starting on the frame for the arms,using light weight aluminium i noticed a lot of robot builders here use hot melt,witch is easy to use ,but makes it very hard to replace gears,and on heavy lifting on arms better to use metal,fiberglass may work ok,but not as strong as metal frame hardness # is much lower but might work ok in josh's design will have to wait and see