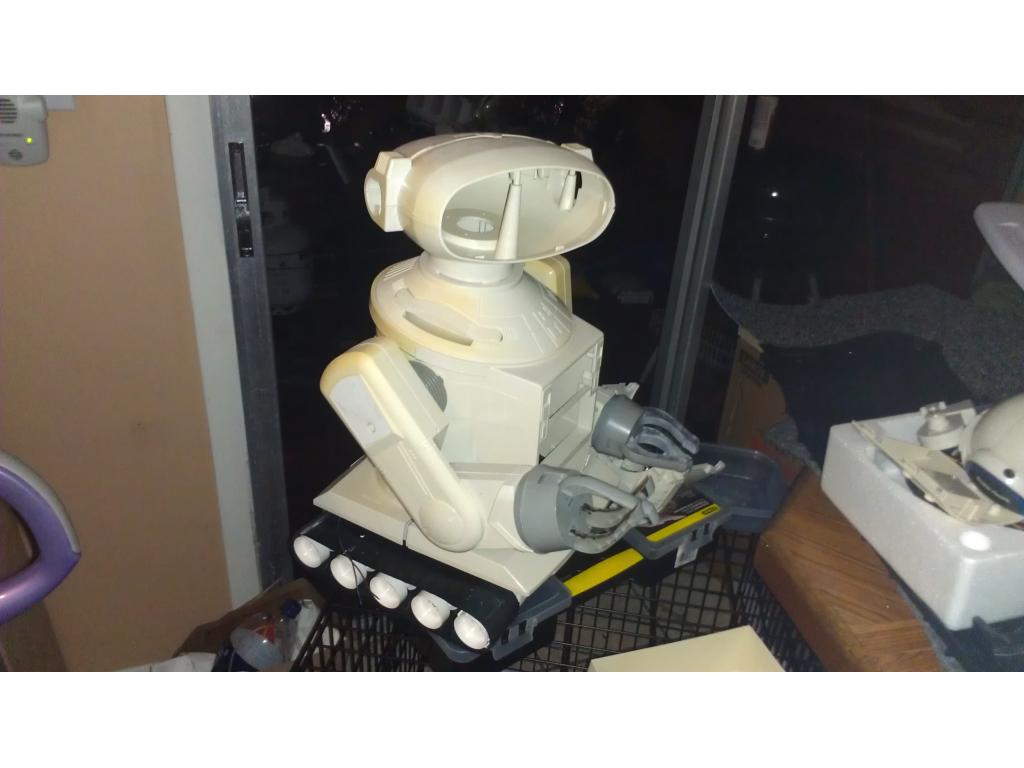
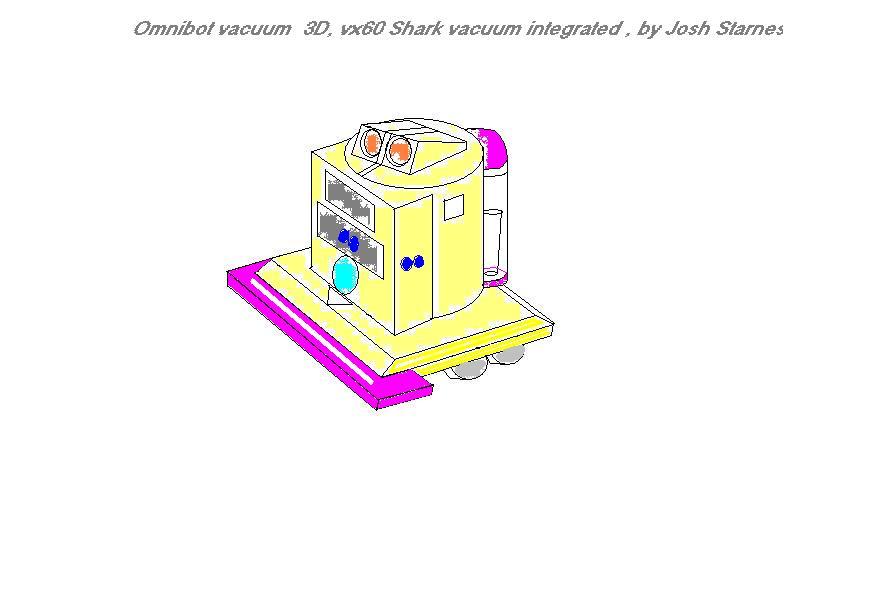
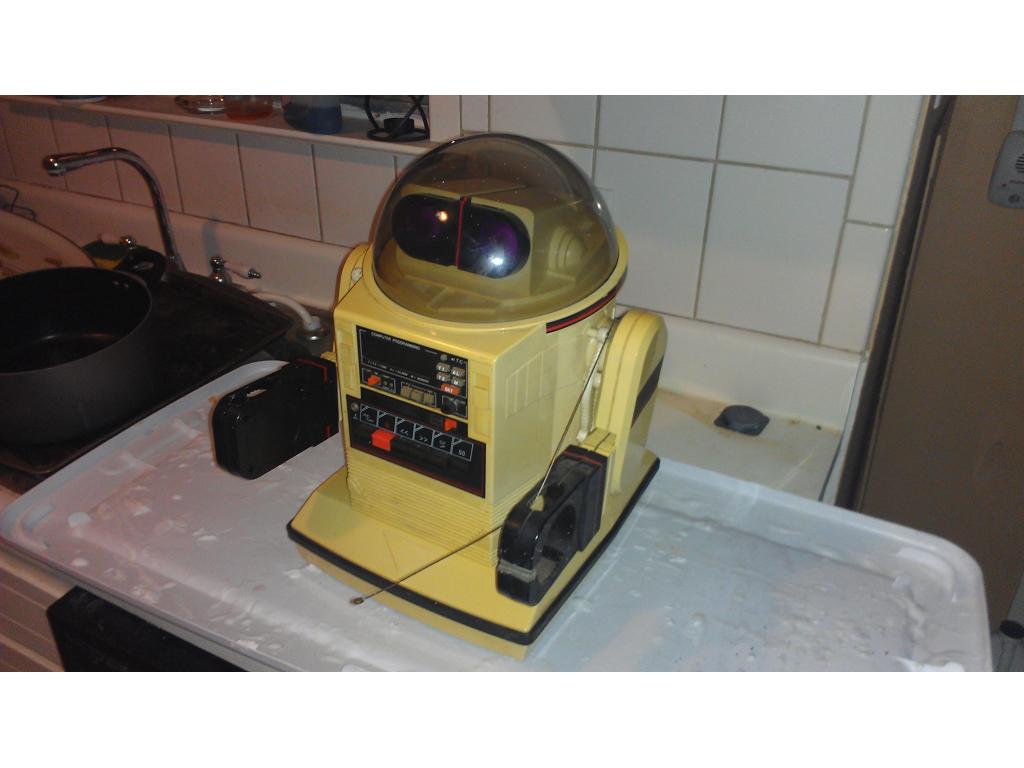
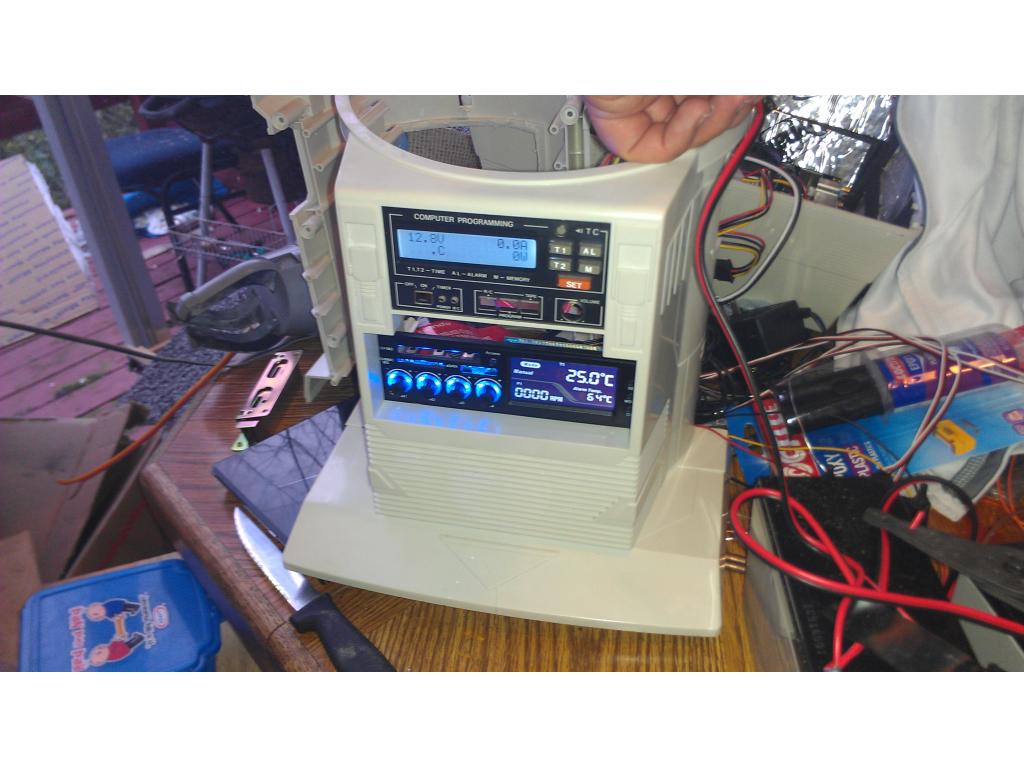
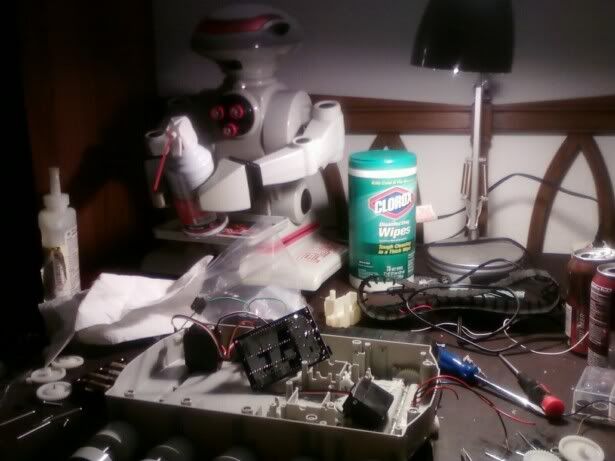
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.

@ @robotmaker I can file teethe with a file guide to perfectly match pitch and I can balance them , but if you can smelt brass or aluminum gears for me that's great!
You could cast copys of your original gears in Aluminum filled urethane or epoxy resin. I hear good things about Alumilite & Smooth-On
I'm in need of 3 sound sensors. https://www.pololu.com/catalog/product/1620
Also I need IR detectors that are like dark tinted LEDs , here is a link , I need 5 https://www.radioshack.com/product/index.jsp?productId=2049723&filterName=Category
Josh I have a sound sensor from ottobot it's just two wires.
when i need gears it much easy to find a gear already made,like boston gears,or servocity and make my own gear box,saves money and lot of time and professionally mostly only time i need to make them at work is when a special gear is needed
Thanks josh , i thought the motors would be different . I will make my own drive train for my omni.
Steve_C.
@JOSH hopping after next week to start on my robot designs,still got some house changes to make making another room on to my house for my robots and finished with the roof work so soon my omni project will be started
have you used the high torque motors i sent you yet and the dirt sensor it seems the motors handle about 70lbs (35 lbs each) and in the omnibot gear box should be a lot more because of the gear ratio is bigger
I havent used them but will once I get parts back from painters.