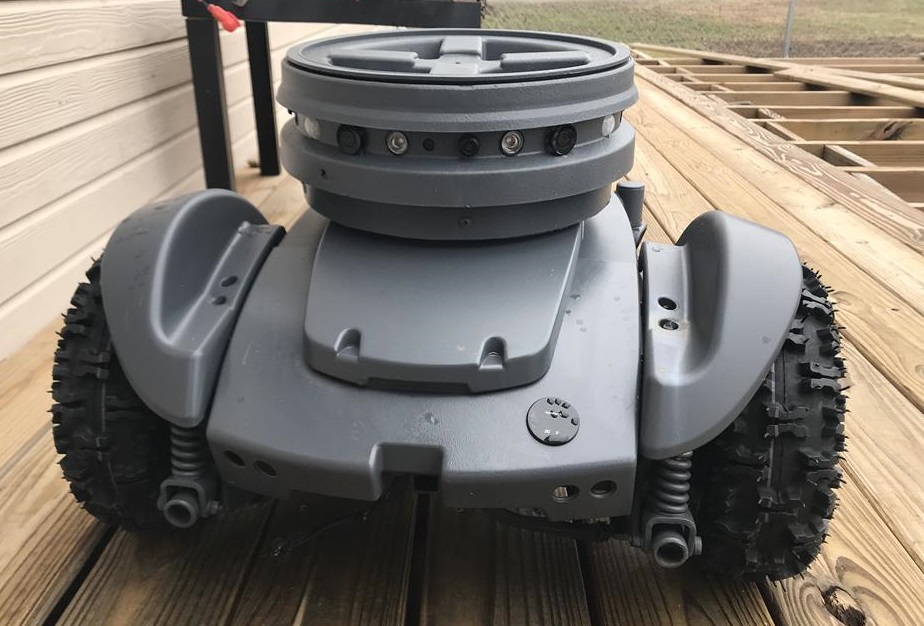
Here is the current look of this project, Super cool update, magpi magazine wants to feature this build with steps how it was done , !
 Camera Device
— Use PC or robot cameras for vision tracking: color, QR, glyph, face, object, motion; record video/data, control servos and movement, run scripts
Try it →
Here is the current look of this project, Super cool update, magpi magazine wants to feature this build with steps how it was done , !
Other projects from the same builder.
Robots the community built with Synthiam ARC. Get ideas for your next build.
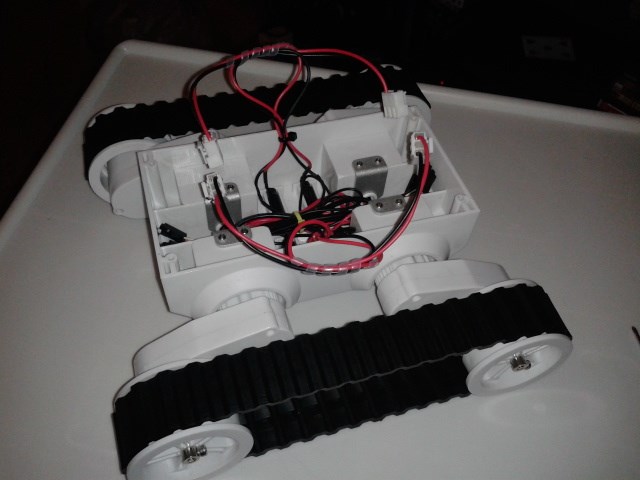
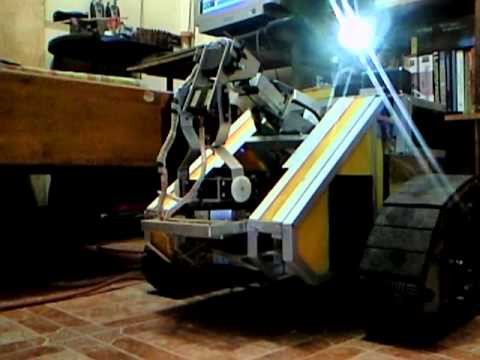

I have picked up a few Jazzy power chairs and pulled the seats off of them. I will further remove stuff that I don't need. I have seen people hack the original motor controllers but I feel like I am better just selling the original on Ebay and buying one made for DIY building instead. My first power chair base project I used a Sabertooth 2x12 ,but I do have a couple other generic controllers I picked up that may work just fine. I will post some pictures, thoughts, goals and parts I have to work with so far. Any input is cool.
You have two threads with a similar subject (wheel chairs). Which one you will keep updating ?
I dont see the second one , Are you talking about the power chair thread? Because thats not for specifically my projects but general ideas for power chair robots. Thats a free for all discussion.
This is a Project showcase for the Outdoor Security robot build.
I missed the "Project showcase" tag.
General Goals
a mobile platform that can patrol a set routine
Motion tracking , robot turns towards movement and tracks that object/ person
3-4 cameras recording 24 / 7
run without outside power for at least 12 hours, but the goal is excess of 24 hours.
-Even in the even the robotic size of the electronics fails or the battery runs dead, there is a backup that keeps the cameras on and recording.
-Recording both locally on the robot itself and also wireless video sent to a recorder that I will probably setup with another raspberry pi.
Live access to the cameras over the internet
1 tb hard drive dedicated to every camera, covers recording in HD for at least a rolling month. Recordings in 10 min intervals.
-Dual battery setup, one battery for the drive wheels , motor controller and ezb Lithium battery 10,000 mah packs for each camera
-Safety Stop switch that cuts power to motor controller in the event of an emergency, but everything else still records.
-Create a water resistant area protected from spashing and weather for the electronics
-make some kind of seal where the panels come together
-GPS geofence alarm and active tracker
GPS tracking unit, with built in battery so it tracks even if the main battery is removed.
https://www.ebay.com/itm/232479396529
No IR Raspberry Pi 5mp camera with 130 degree lense