
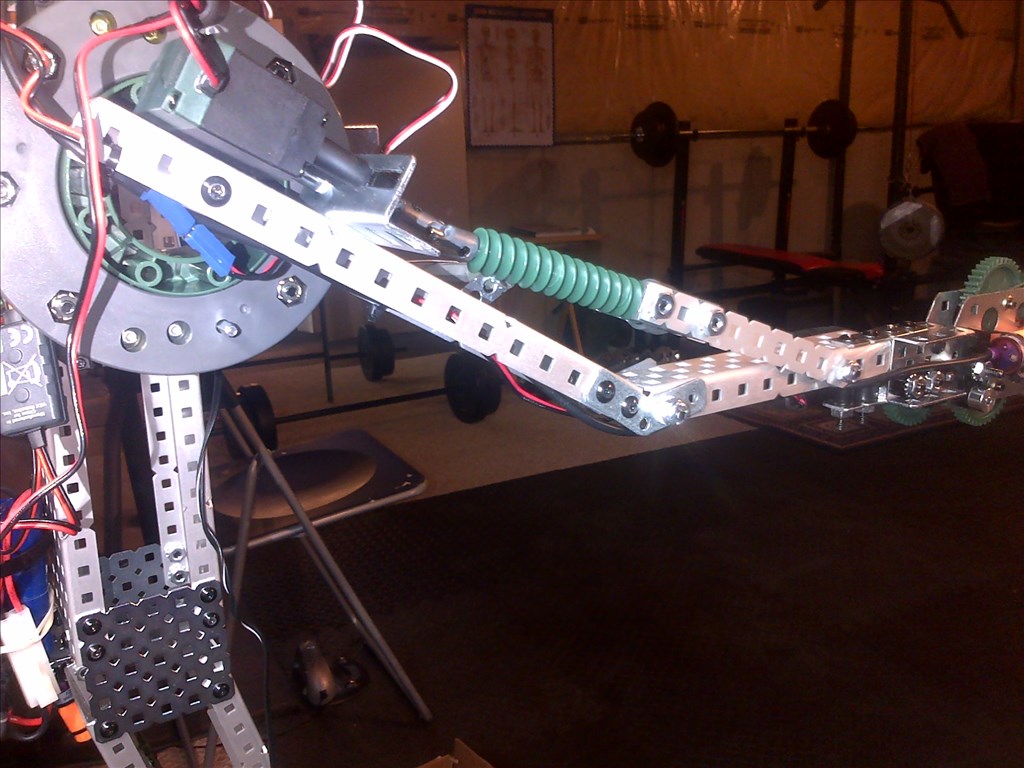
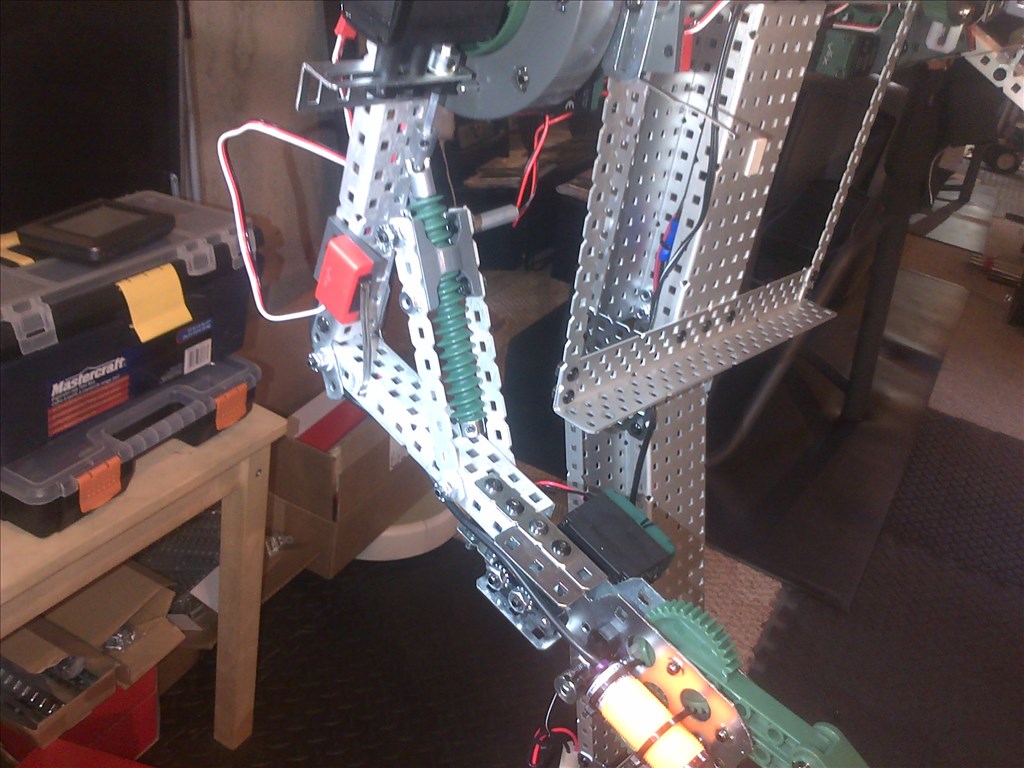
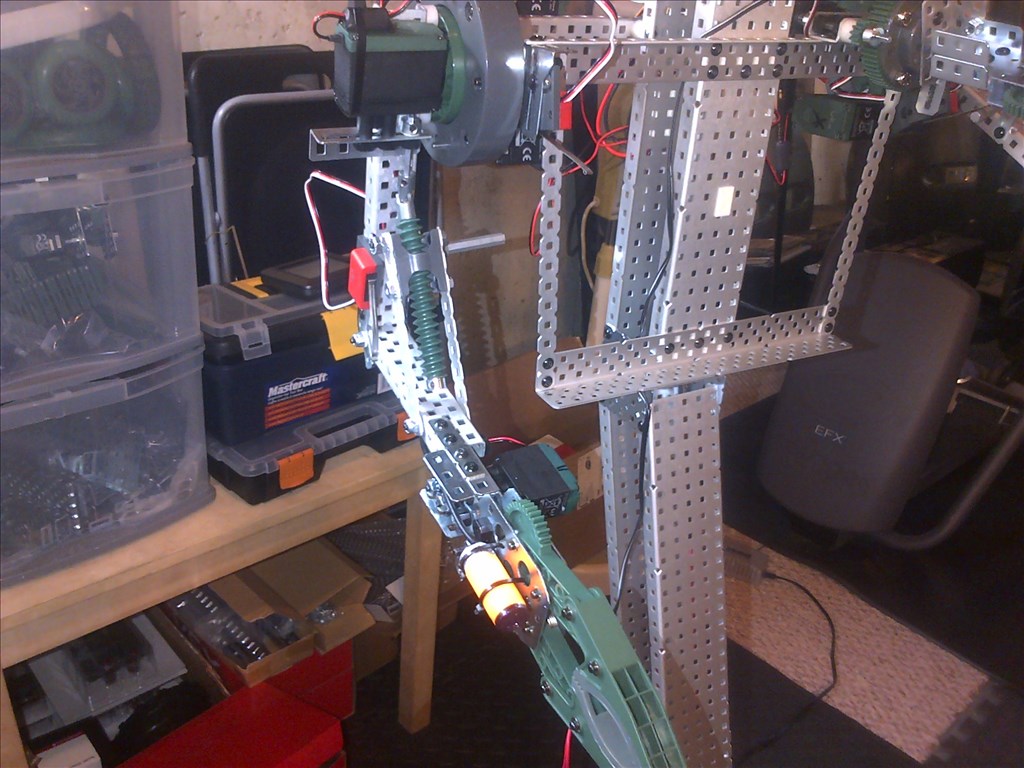

In an earlier thread Doombot had mentioned he may put a ping sensor on his robotic claw to sense and pick up objects automatically... Well, I had a moment of inspiration so I thought I would try and knock up something... So check it out... a simple prototype of my version of object detecting robotic claw...
By Dunning-Kruger
— Last update
Discover more robots
Wallekid1's Wall-E Made From Scratch
WALLE replica: custom reinforced tracks, moving arms and neck, independent track drive, LED eyes, random sound notes,...
Andy's Antonn
Antonn robot prototype moves, speaks and reacts to 30+ voice commands, tracks with nose camera and moving eyes, controls...
Sfoy's My Frankenbot - Robosapien, Hearoid, Ottobot Head
Build a custom hearoid omni bot base with mini-ITX, acrylic enclosure, IR sensors, cameras, pan/tilt, EZ-B integration...

Need to rebuild your youtube video, right now it's marked private
Not sure how that happened... does it work now?
Nice, thanks!
Hey Richard thanks for the vid! and its kinda "crab-like" with the ping sensor eyes
Thanks for the mention bud! However it's not an original idea of mine. I blame the roomba beerbot for the inspiration! Mine is located underneath the claw though, so it is out of sight....
Thanks guys... I agree the ping is either too big or in the wrong place... Going to tinker more and see if I can't make it a more elegant design...
Nice video. I like the idea of putting an IR sensor in place of the ping sensor also. I also would suggest maybe usiing pressure sensors in the claws to aid in determiningamout of claw pressure on the softer obects.
Pressure switch is a good idea... I am working to integrate this (and more) into my current project.... I will update as I progress... thanks for the comments....