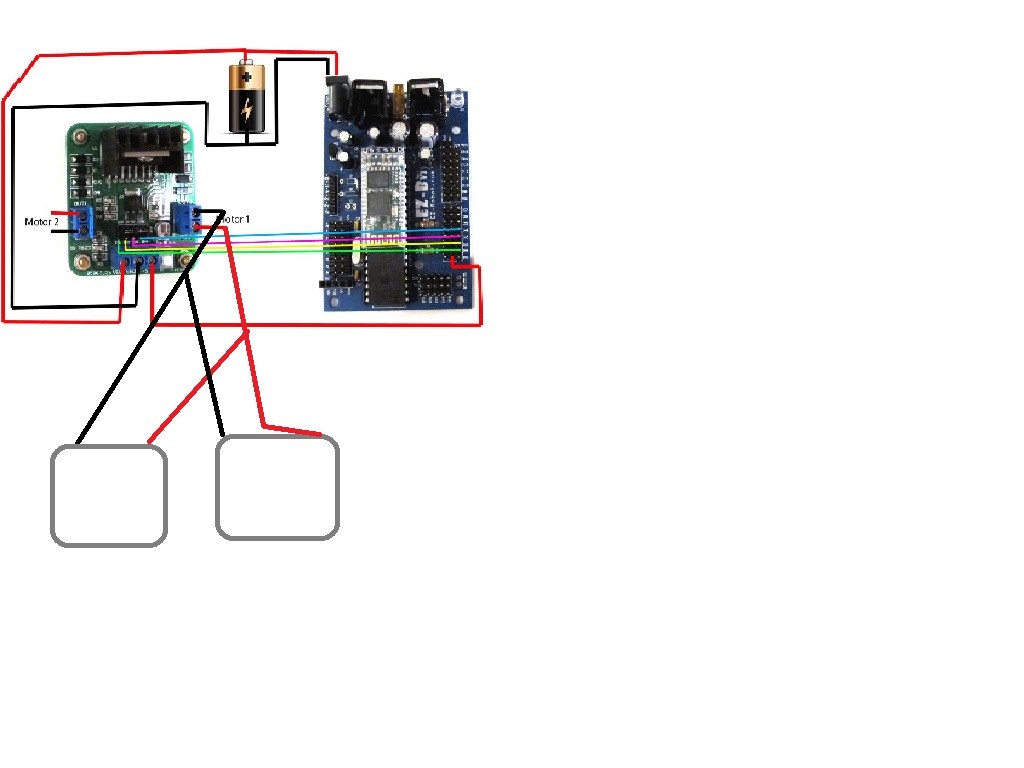
modifying a rc car(truck i guess) to operate off a sabertooth and the ez-b. Any responces are welcome
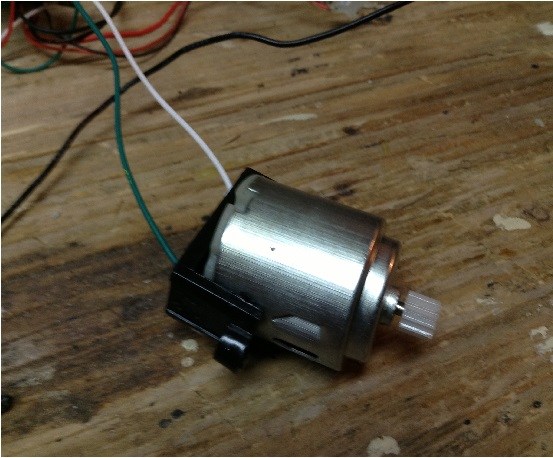
Specs: Sabertooth 2x12 Ez-b V3 2, 2.8-3A dc motors w/6A peak standard servo for steering
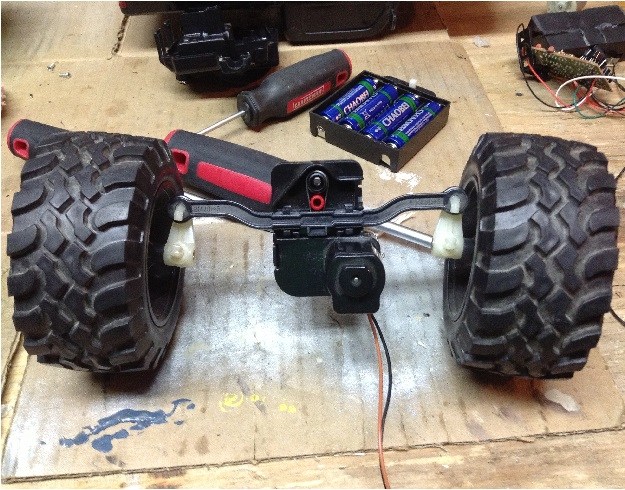
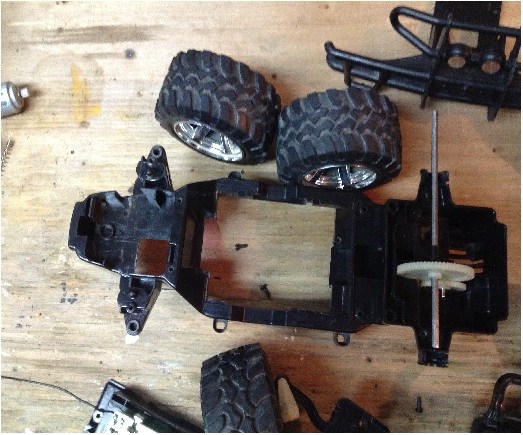
Rc car torn apart:
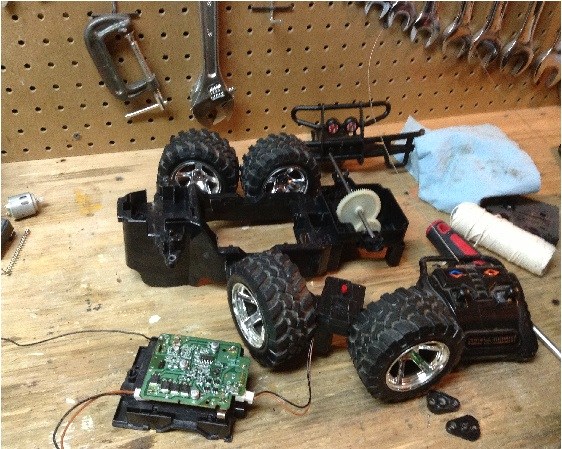
the main body. the wheels were driven by one motor and gears. going to modify and put 2 motors directly(with gearboxes) on the wheels. then attach to the sabertooth and yadi yadi ya.
By CardboardHacker
— Last update


Discover more robots
Putt's Shorty
Custom EZ-B bot built on a Parallax BOE base with a LynxMotion torso and brackets; work-in-progress assembly
Ezang's My Tightrope Robot Without The Squeak, Sorry For The...
Tight Rope robot without the squeak - enjoy a smooth, silent balance performance
Pittom's Rc Rock Crawler
Custom AXIAL XR10 rock-crawler with Novak M2 ESC, dual 55T motors, Acer PC, Foscam IP cam, sensors, speakers, onboard...

quote 1: scripts, wii remote, voice commands, autonomous.
quote 2: figured it out an hour ago
#3: will setting the turning values to 0 disable turning with the sabertooth?
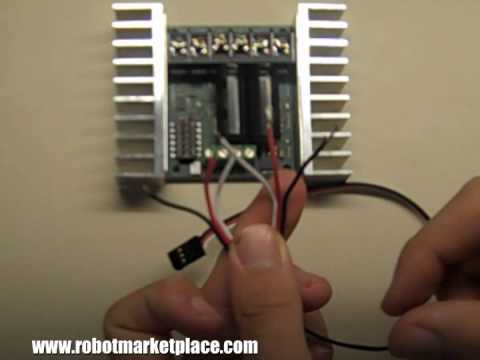
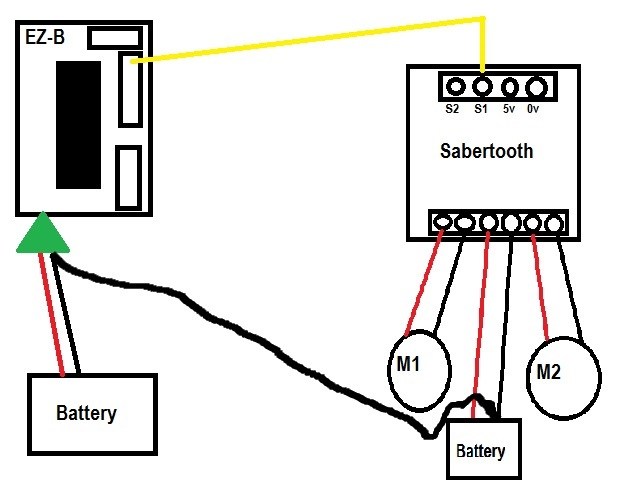
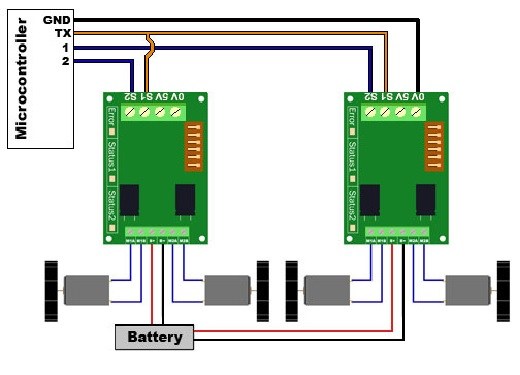
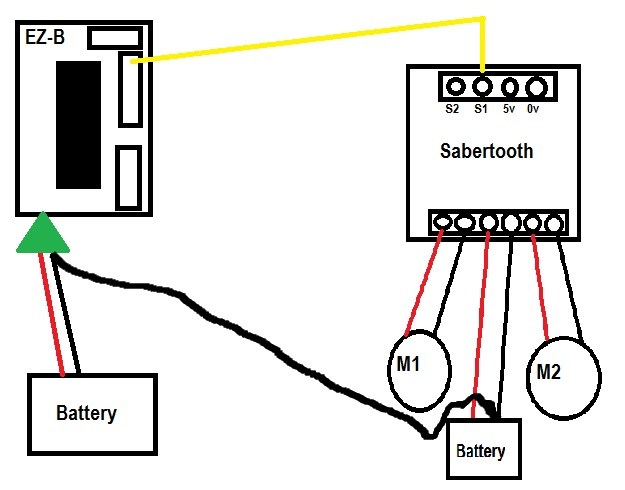
#4: i need a diagram/pic of a sabertooth connected to the ez-b
As I just spotted by @Rgordon in a different topic.
So I would say to set them at 64 and 192 but can't be 100% as I don't have or have ever used a Sabertooth.
0 would confuse it so it wont turn, would you not think?
What is with the values being different?
I don't think there is a position 0.
If you have no need to turn using the sabertooth couldn't you run both motors from one port? Or is the amperage too high?
amperage might be too much for one port
1 motor is 2.8-3A running and 6A jump at start 2 on one im not so sure about.
i need a diagram of the sabertooth connected to the ez-b.