
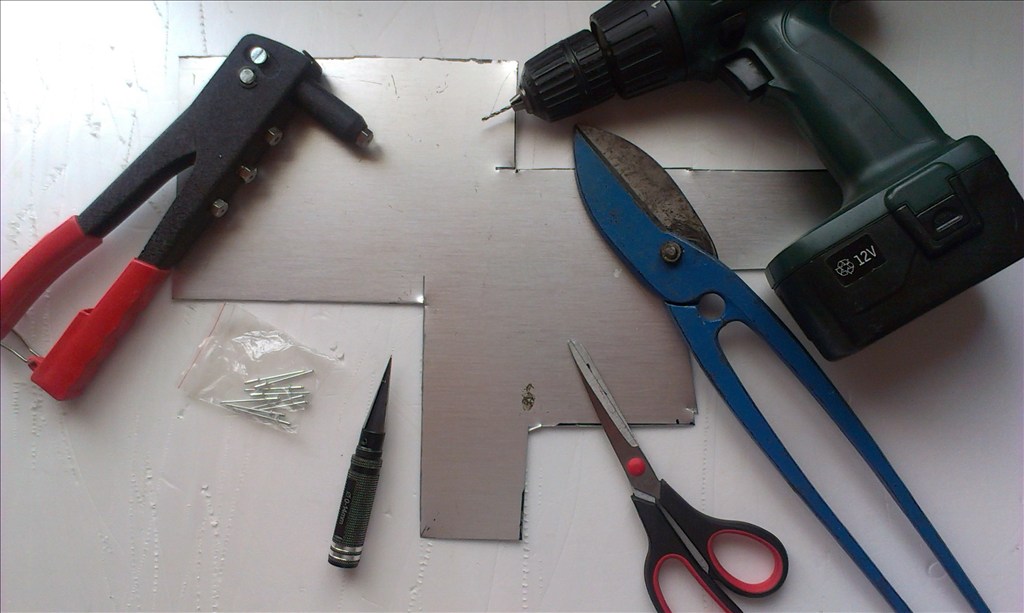
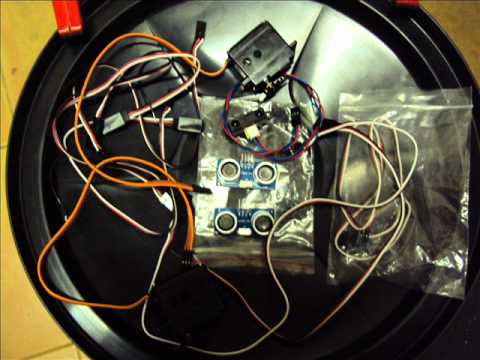
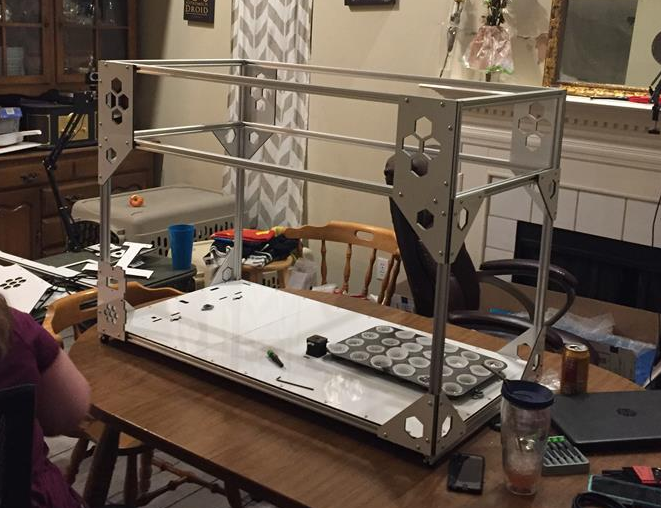
This is my new pocket robot: Navigator. Constructed from aluminum, cut with scissors, and assembled with rivets. Powered by a 11.1 v lipo battery, 1600mah passing through a regulator 8v (good voltage without fan) to feed ez-b. All heatsinks remain warm and has a great autonomy in the current configuration. My purpose is to experience in navigation with only the essentials, and start with a ping sensor and squeeze the most of what can be achieved. The second phase incorporates collision sensors with switches on the side of the robot and delanera. Then I would like to taste the lateral measurement with a ping sensor on each side of the robot (these would be fixed) and thereby expand the project in a modular, finishing with a camera on an upper floor, compass, etc. ..
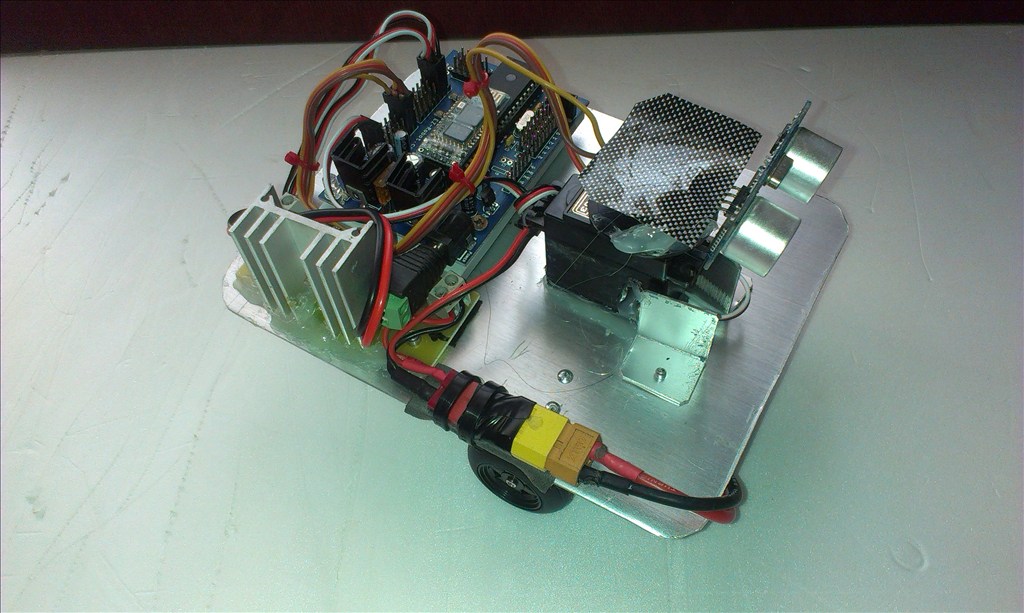
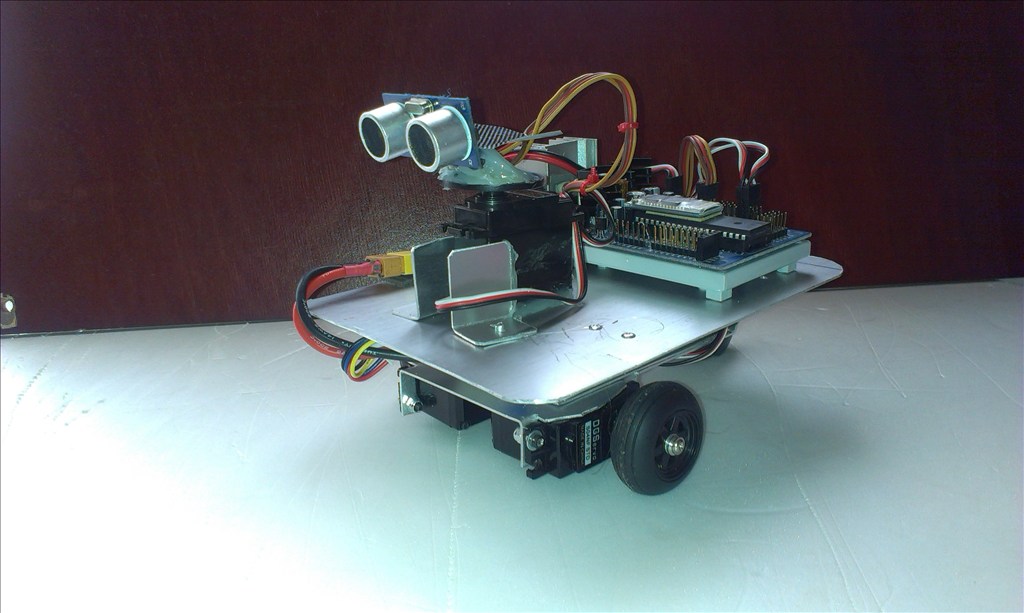



Cool little bot
In this wonderful pastime can be used almost all, this is the first chapter, is also in the cloud:MinirobotNAV.EZB
Cool robot!
Could you take a video and post it. We really like videos - Josh
As always, you're amazing R2D2 ! Nice robot. My Verop platform was intended to do the same thing. Basic navigation and developing algorythms. I hope to post some new pics soon of my EZ-B controlled lawnmower based on that platform. I'm waiting for my new kit (quite some time now)...
Very friendly Phg, I'm thinking about making videos Josh, in fact I would like to capture the video from the roof down to see the navigation in a room and then apply the quick-motion effect to video. I do not think it takes much to do, less than 10 years, haha??.
Yeah, tell me about it ! Time is what it's all about these days... Anyway, I'm looking forward to see your videos. Please hurry.... ;-)
A combination of radar ping and a dash of random spins to the left, this combination has a tendency to approach the walls in your navigation. The script makes random sometimes enter into a silly robot is at loop when in a corner, making it take longer to get out of the corner, but sometimes acts as an intelligent refine the trajectory, some magic. The video speed is doubled: