

David mcsdaver
I was born very young, but that didn't last long. Even when I was little I built robots. I used cardboard and anything that looked futuristic. The toy robots I built all have moveable parts. When I got a little older and able to buy motorized toys I began making robots that moved. I used photoresistors, relays, motors and toy parts to build light seeking robots. I also hacked some rc cars and built a large robot named Max. He had two working arms, a drive system used to drive around and a cool looking head. This was years before micro computers, Omnibot robots or EZ-B. Then I bought a 6 channel RC system and made my large moble robot arm. It could reach all the way below floor level to on a counter top. I used old metal gas station signs to build the arm and power wheels motors to make it move. A bike brake made a great claw to grabbing items. The robot had a multi axis wrist. The robot had 7 motors so I used a muti contact switch hooked to a servo to make controlling everything possible. The RC landing gear switch worked great for the robots head light. I bought an extra rc transmitter and began redesigning the controls to make controlling a walking robot possible, but the transmitter died on me. When home computers became affordable I got one and using a bit of knowledge I had learned from a RadioShack electronics kit and transistors I built a robot controller to use with my Commodore 64 computer. I had found out that I could turn pins on and off on a port on the back of the C64, so I made a board with transistors and relays to control motors in my robot. I took a toy motorized toy crane and rebuilt it into a robot arm and added a plastic claw. I wired the motors to my robot controller and began programming the computer to control the arm. I used the joystick ports to send feedback to the computer as to how the arm had moved. The joystick ports could read 4 potentiometers, and 10 buttons. I added limit switches to the robots claw so the robot would not break its self. I built a wooden base with the drive system taken from a large toy robot, made a cardboard body and head with the arm coming out from between the robots eyes. Sadly with the computer and a power inverter on board the was too heavy to drive around. This robot would be easy with an EZ-B onboard. Years later I got a new computer and a servo controller. Then I made a robot arm using servos and tongue depressor sticks. I used the drive system from a toy backhoe and two speed controllers to get the robot moving. A friend named my robot Waver because that is mostly what it did while I was programming it to move. Sadly the robot was tied to my home computer as it was needed to make it work. This was all many years before EZ-B was invented. My next project was building a half scale working C3PO. I built the upper half of his body and one servo controlled arm to do a test. His head was made from what was called a half scale C3PO helmet. Much too small for anything to wear, but it looked amazing. I cut the neck from the head and added a servo in the head so it could look up and down. I tested the one arm droid and everything moved very well, so I built the second arm and did a test and he could lift both arms at once as he looked around with no problems at all. Then one day I decided to design my own humanoid robot. I took C3PO apart and began building Dave. He is a humanoid robot from a story I am writing. I found out about EZ-B and ordered one with the camera and servos. I spent my vacation testing my EZ-B. I made a small rover robot using the included wheels, continuous rotation servos, sonar, a small wooden board and the wireless camera and a hot melt glue gun. Everything was easy to control and the robot moved very well. Face tracking and voice control all working in a short time. I decided this is what my humanoid needed, so I took the test robot apart and added the EZ-B to Dave. I used the upper body of a Robosapian V2 robot just to have a body for testing the robot. I wanted the robot to look like the robot in my story so I thought about how I could do that. I sculpted his head and made a plaster mold and then pushed a sheet of hot plastic into the mold. This plastic could be melted in hot water and shaped by hand but cooled quickly so the mold helped get the shape right before t was too cool to shape. I got some eyes from China and continued to work on my robot. Then I found out about 3d printers and ordered one. I had designed the robots in LightWave a 3d animation program and found some free plugins to add STL file support. Sadly the files I made would not slice correctly. New Tek announced a major upgrade to LightWave and I noticed it included 3d printing. I got the $500 USD upgrade and then rebuilt my models and tested them in the STL slicer and they looked good, so I 3d printed my robots head. The print came out amazing so I worked on his upper body, but it was too large for my printer. Hmm, even cut in half it is too big, so I did a little more work and with the object turned 45 deg it fit and printed with no support needed. I printed the rest of his body and added the robotic arms, servos for his head and had him mostly built. He still needs legs and more programming to get him to do everything I want. Thanks to EZ-Robot my robots amazes and entertains people.
Achievements

-
 2012-06-07 - joined Synthiam
-
 2012-08-16 - joined your first forum discussion
-
 2012-08-18 - created first new question
-
 2014-06-04 - posted a robot project showcase
-
 2014-08-18 - connected ARC to the cloud
-
 2014-09-03 - shared your first photo in the forum
-
 2014-09-09 - attempted to help a fellow robot builder
-
 2014-09-10 - created a custom avatar
-
 2014-09-11 - shared your first video in the forum
Latest submissions
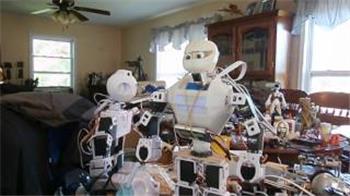
My New Ez Robot Bob
I have bought a large number of EZ-Bits with HDD servos and started a new robot project named Bob. Bob is a mix of 3d printed and EZ-Bits with a V4 EZ Robot controller! Video coming... 13
 6 k
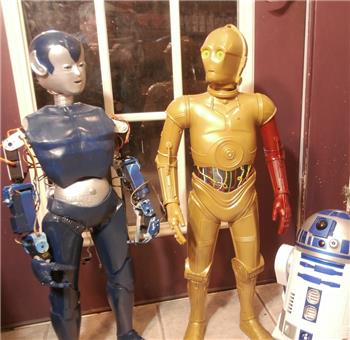
Building A Working C3po Robot From A 31 Inch Tall Toy C3po
This C3PO is about the size of my robot Dave. My new EZB has shipped and will be here soon. I am working...
2
4 k
Auto Position Wont Work With Second Ez-B Board.
I have no trouble getting the Auto Position to work on my first EZ-B for my humanoid, but there is no way to tell the software...
5
3 k
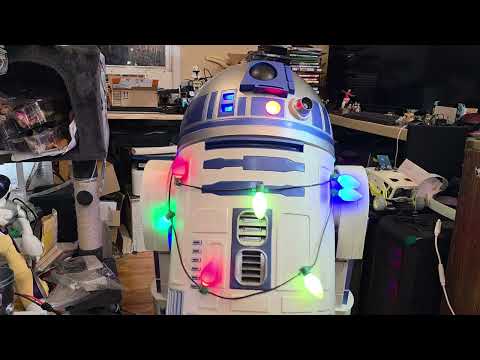
David's Home Depot R2D2 To A Real R2D2 Robot
Convert a Home Depot animated R2D2 into a mobile robot: battery-powered dome, AR-activated lights/sounds, bumper-car motors and RC...
6
2 k
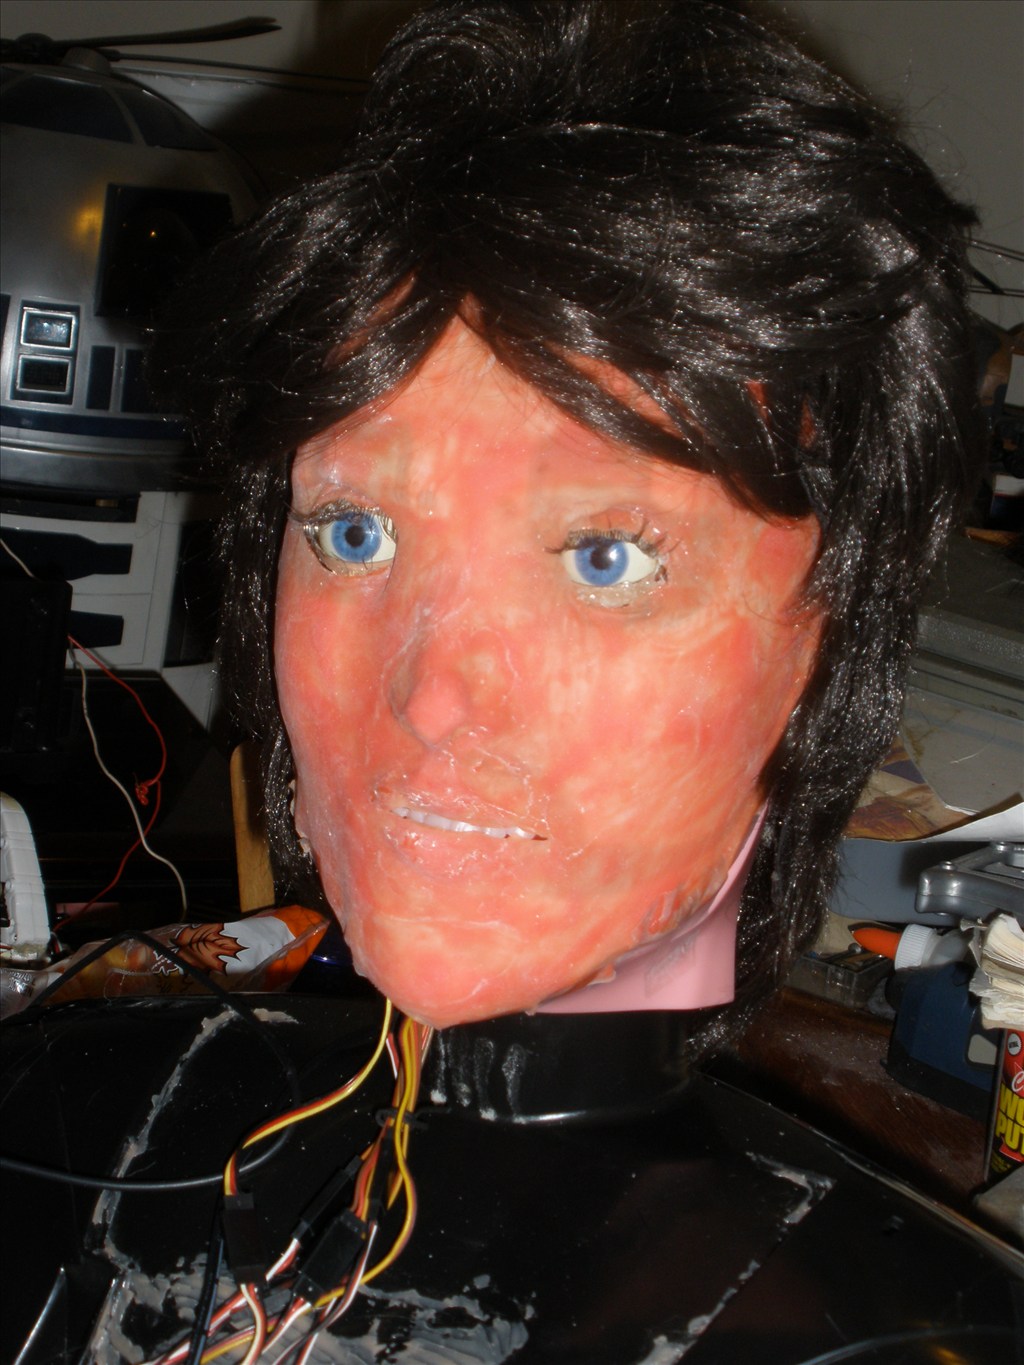
David's Android Project Jen
Build an advanced android using EZ-B controllers, molded mannequin skin, multiple arm motors and powerful linear actuators for lifelike motion.
38
14 k
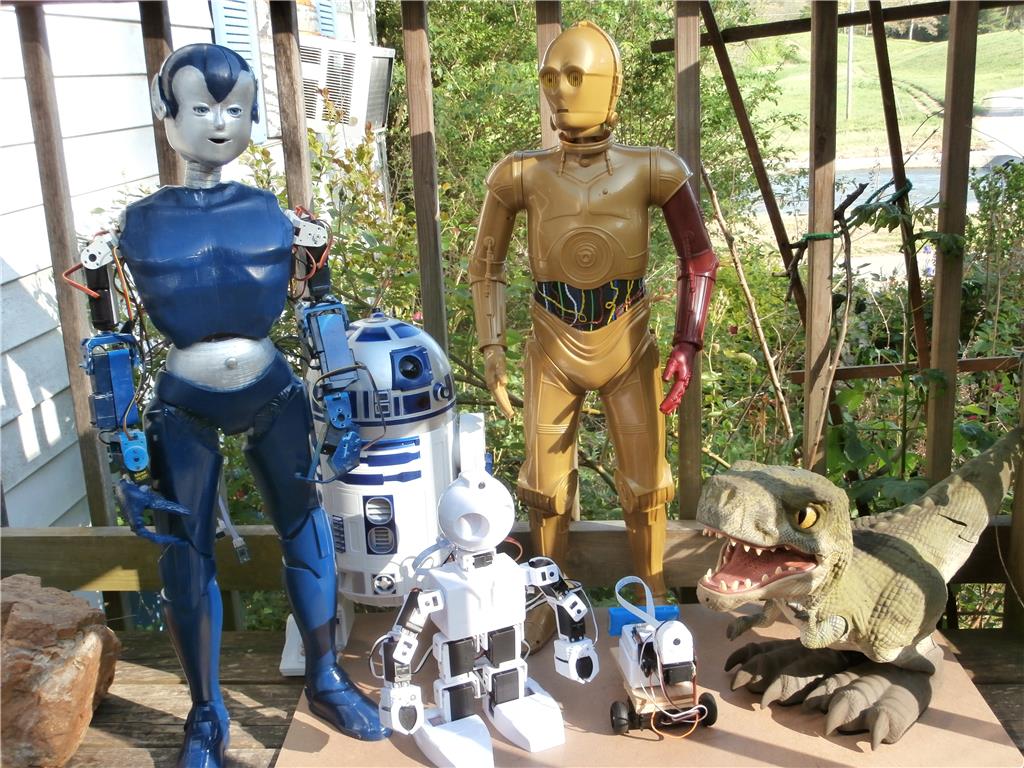
David's C3po Ez Robot
Build a C-3PO robot with an EZ-Robot brain and servos, adding hearing, vision, speech, motion and interactive behaviors.
26
10 k
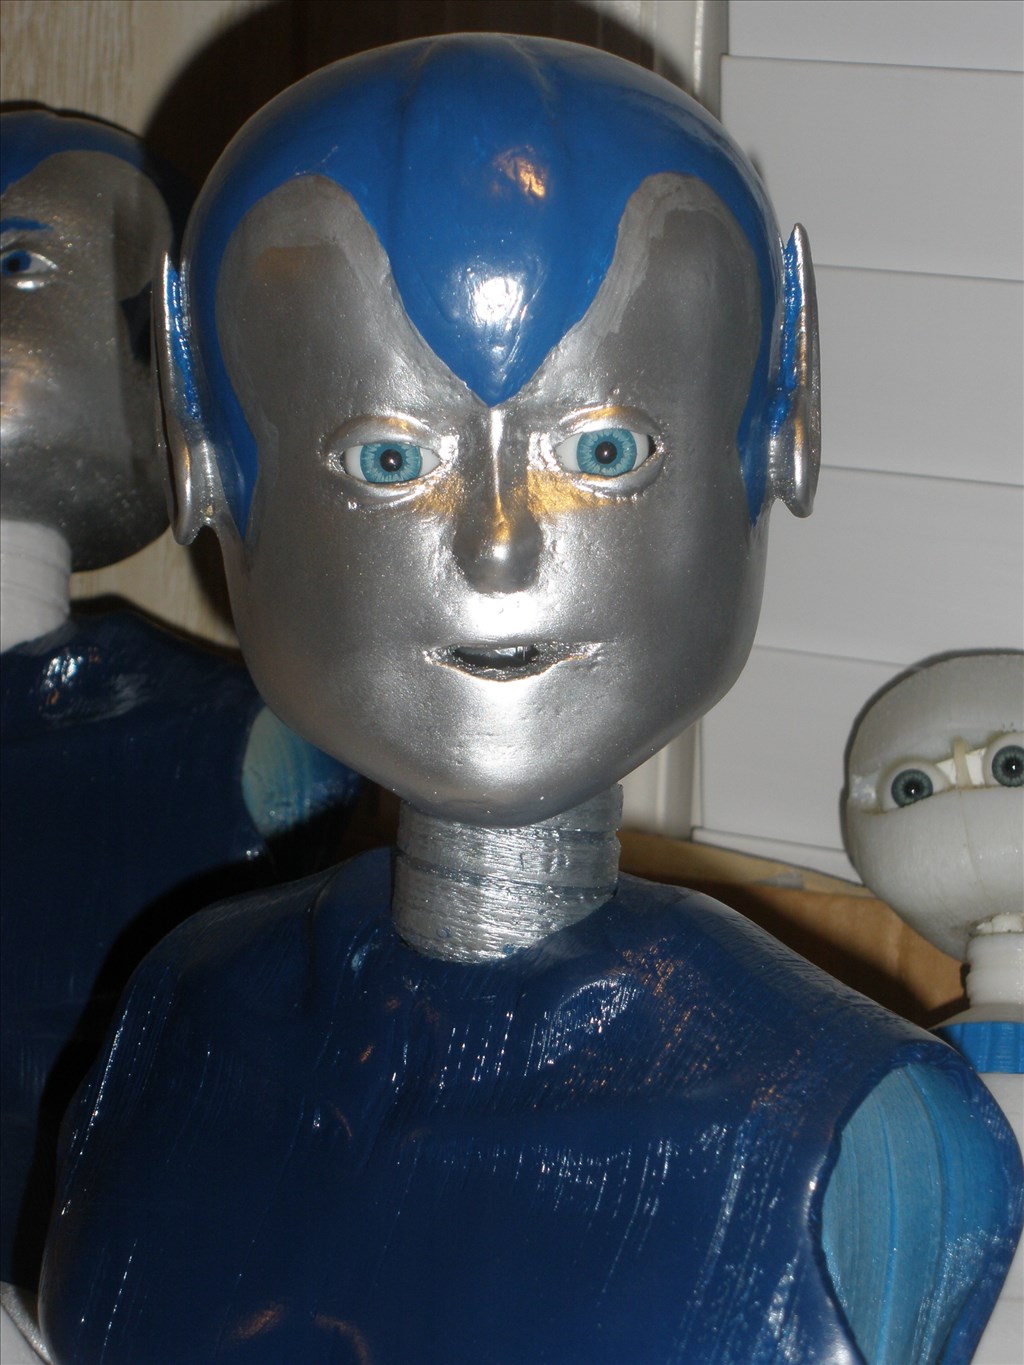
David's Humanoid Robot
Robosapien V2 upper-body robot with homemade 7-servo arms and Micro Explorers story about tiny robots that combine, self-repair, and gain human traits.
178
36 k
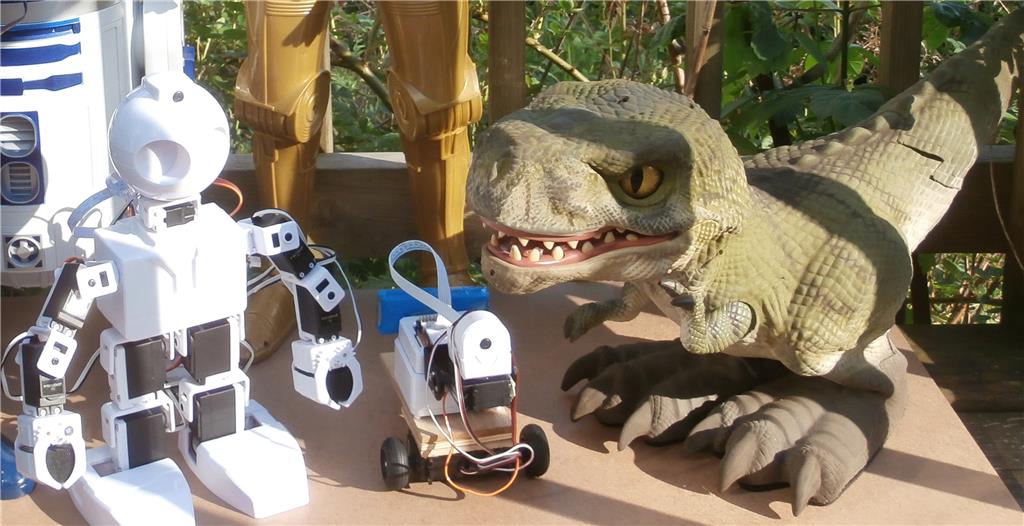
David's Ai Dino Robot
Upgrade a toy walking dinosaur with an EZ-B brain to create a smart robotic pet, unlocking expanded behaviors and capabilities beyond the toy.
9
8 k
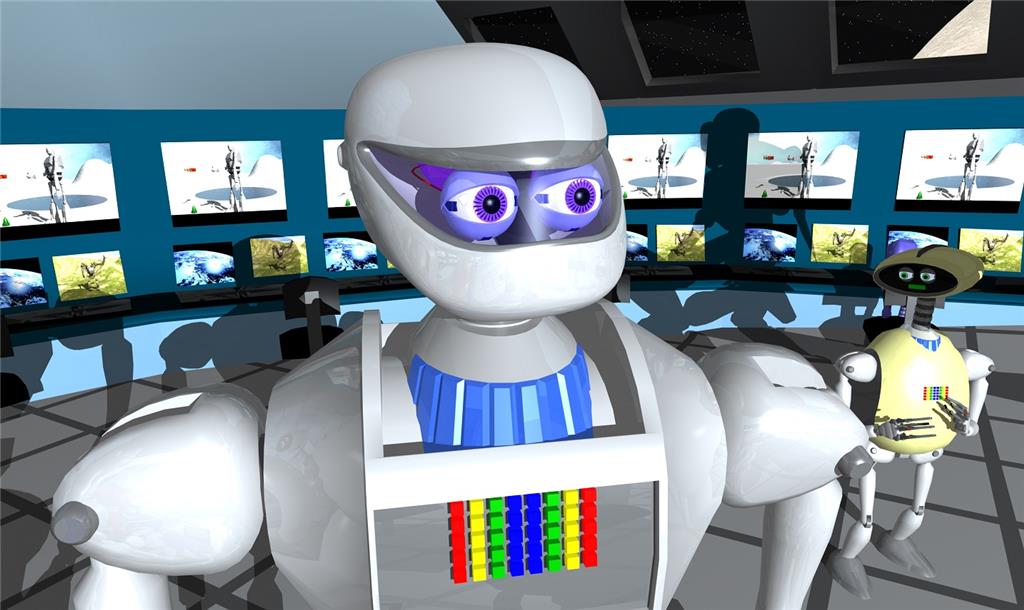
David's 3D Printed Ez Robot Bob
Bob, a 3D-printed EZ robot built with EZ-Bits, 3D-printed parts and hot melt glue for DIY robotics and easy customization
12
6 k
Dave1ezbv4gyro
Humanoid Dave uses his EZ Robot cam to track faces, respond to voice commands, wave, high-five and take objects handed to him.
0
3 k
Davev4july2017
Humanoid Dave uses his EZ Robot cam to track faces, follow voice commands, wave, high-five and grasp objects as he learns new skills.
0
2 k
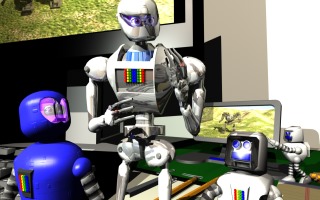
Bob
Bob humanoid robot uses the same ports as JD for similar functions; his size and shape require adjusted actions and calibrations.
0
2 k
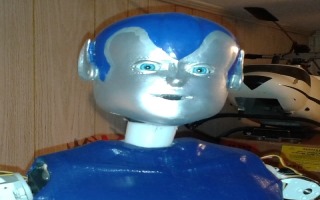
Davev4may2017
Dave Humanoid V4 May 2017
0
2 k
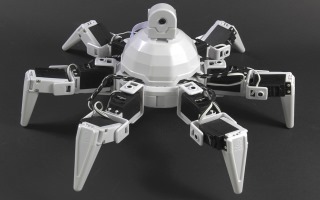
Six1
EZ-Robot Revolution Six starter project with step-by-step tutorial at ez-robot.com to get your Six up and running. Updated by Dave.
0
2 k
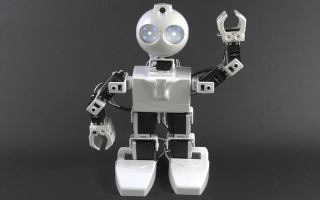
JD
Official Revolution JD example project with EZ-Robot tutorial course to get your JD robot up and running.
0
2 k
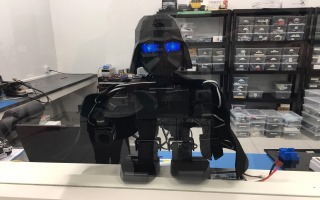
Darth Jader
Modified JD 'Darth Jader' with black-painted brackets and a head cut to fit a camera, RGB eyes and neck servos-assembly requires hot glue.
0
2 k
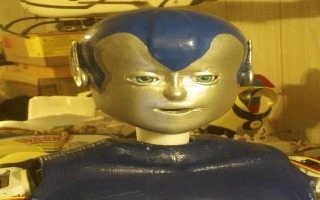
Davev4nov
Humanoid Dave uses an EZ Robot cam to track faces, respond to voice commands, wave, high-five and take objects held before him and is learning.
0
2 k
Davev4nov2
Humanoid Dave uses an EZ-Robot cam to track faces, obey voice commands, wave, high-five and grasp objects while learning new skills.
0
2 k
Dave1ezbv4nov
Humanoid Dave uses EZ Robot cam to track faces, respond to voice, wave, high-five and grasp objects-still learning.
0
2 k
Dave2ezbv4
Humanoid Dave uses a webcam for face tracking, follows voice commands, can wave, high-five, take objects held before him and is learning new skills.
0
2 k
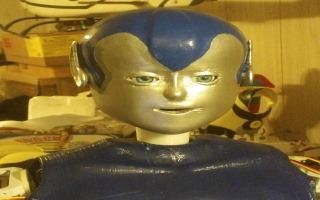
Dave1ezbv4
Humanoid Dave uses a webcam to track faces, responds to voice commands, waves, high-fives and grabs objects held before him while learning
0
2 k

Androidjen3
Android Jen face, mouth and neck control - early-stage facial control project
0
2 k

Androidjen2
Control Android Jen's face, mouth and neck - early-stage control project for developing her facial and neck movements.
0
2 k