



hi
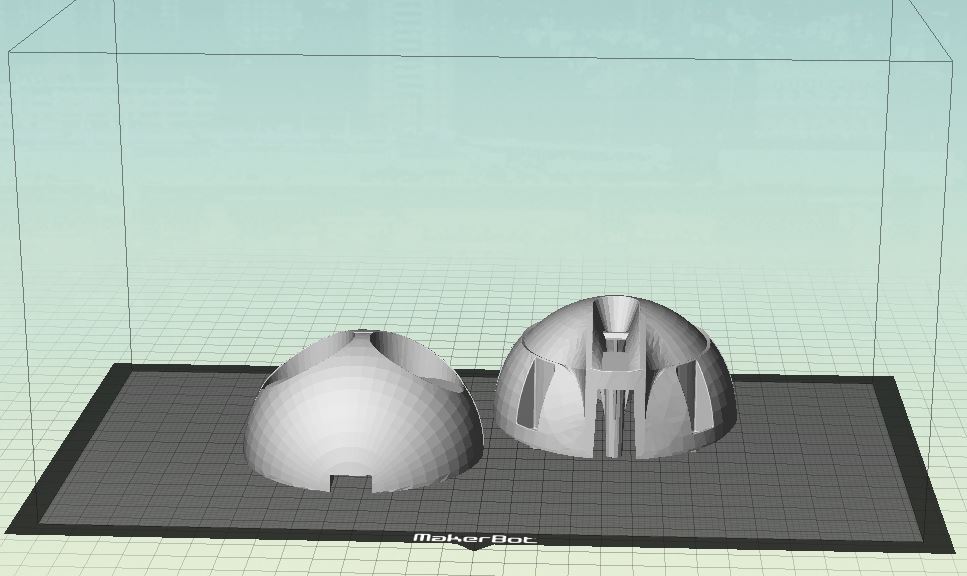
has anyone printed a jd head?my question is ,how do you print the head on the printbed?
thank you
 ESP32_MPU6050
— ESP32/Arduino EZB firmware with MPU6050 support: provides accelerometer angles and Yaw/Pitch/Roll gimbal servo values for stabilization and scripting
Try it →
 Resolved by Jeremie!
hi
has anyone printed a jd head?my question is ,how do you print the head on the printbed?
thank you

Oh man those 'advanced Chinese robots' are just an insult to people that create.
hi perry S
idd , i was actully lookin for this guy remote . he has an antenna .
video's are back on yotube.
finally with the help from synthiam i can control the contineus rotation perfect . i made a bridge that stands for the inmoov body .just to see what it does . more printing .
hi perry S
what is the purpose of these 4 bolts ?
The purpose for those bolts is to hold the collar to the waist plate. You will notice the collar holds a set screw that engages the waste rotation gear as well. This is how he will rotate at the waste.
Also about the demo video you posted. If you put a pivot point in that cross bar like the inmoov is set up I fear you will start to have problems.
hi perry S
the cross bar is just for testing . i was thinking the 4 bolts are to keep tention between the , top plate and lower plate so the ball bearings wil not fall out .
thanks for your time .
secret hiding for the iotiny .xD also the batt fit in there. turn waist &tilt sides goes on the iotiny.