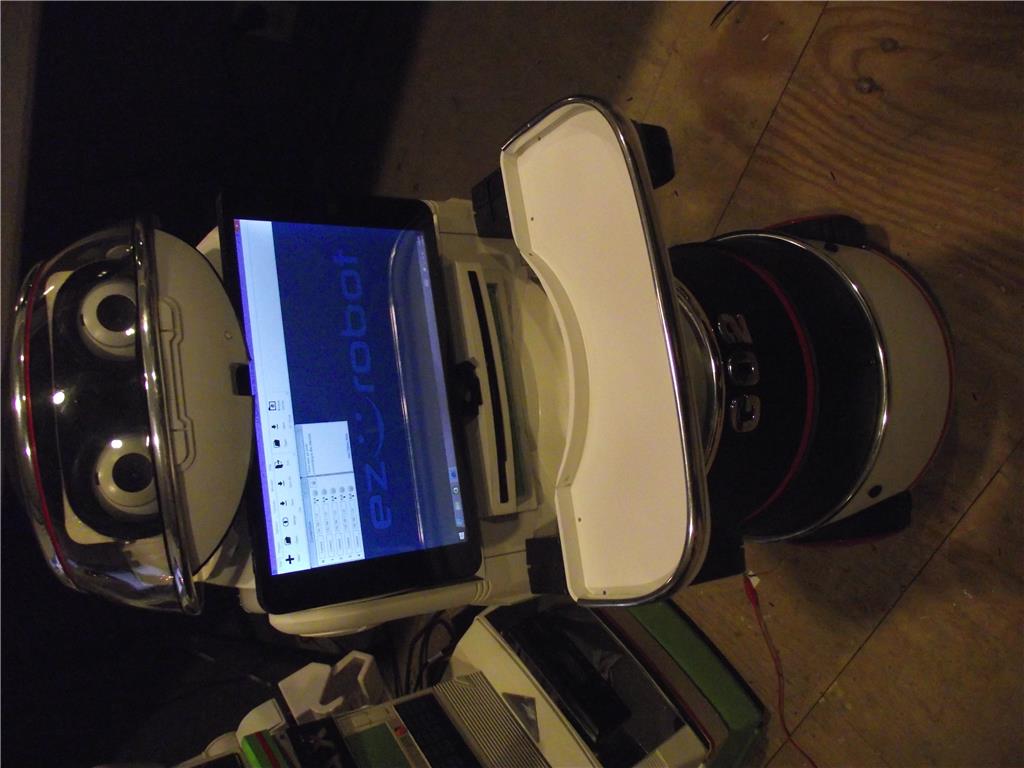
I started working on this Robosapien project with making a new head from a 3d kids space projector. Fabricated face shield form tinted plastic and added leds. Another feature added is adjustable r/c shocks to compensate for the weight of the head(which is very light)..I will use the EZB v3 that i have and the wireless color camera installed in his head. Installed hd servo for head rotation. Hope you like it.
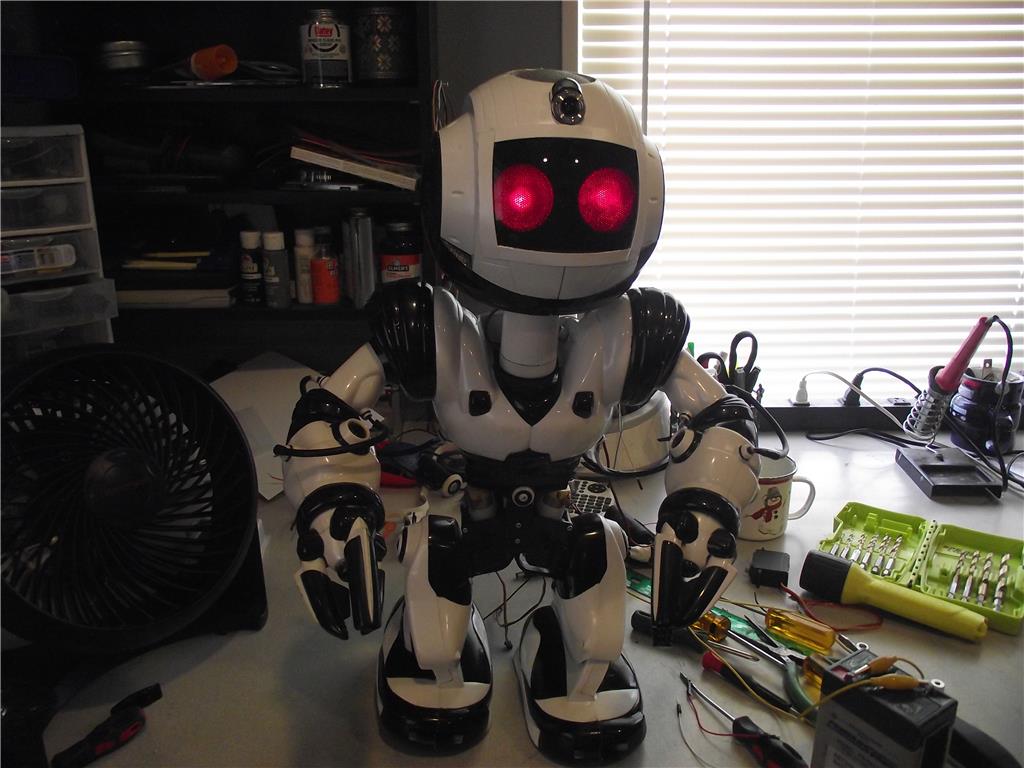


 I was hoping to get some feedback on this project.

the robot looks cool,but why would you change the springs ? its possible he will not walk properly now. the robot needs to be able to swing left to right to be able lift his feet up and move forwart.
Shock springs installed to compensate for extra head weight. It still moves correctly..I am able to adjust the amount of movement..
does the lower body part still fit ?
yes
the robot looks very cool.
@rb550f , You sure do make some cool bots. I love his eyes. They kinda burn into your soul.
That's a great idea using adjustable shocks. I could have used an ingenious thought like that a times. I've got to remember this. Do you have a video of him walking and the shocks working you could show us?
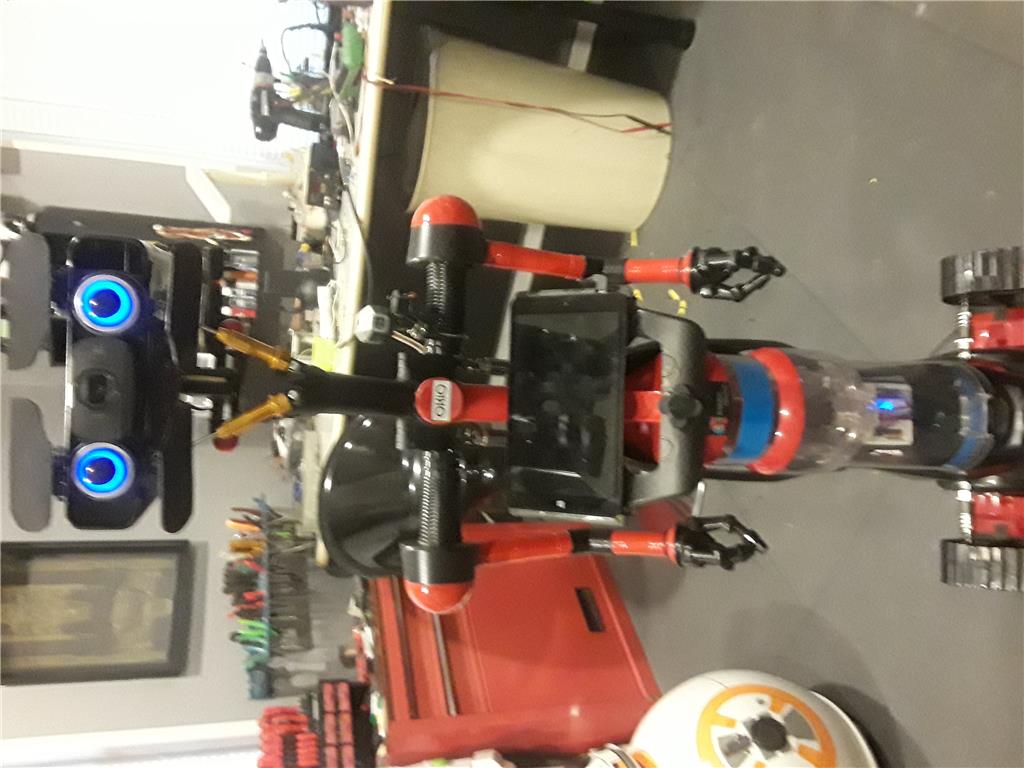
Thanks for the response. I have added a pan/tilt servo assembly and works great..Also added a backpack cover for the EZB v3. I have two serious problems..1 is power .Cant find space for added battery power. 2 his walking is poor even without the mods. I think he looks great and scripted some more of the robosapien and ezb servo commands .I am thinking about making a lower drive base like the new lost in space robot (wheels or maybe threads. This would give me plenty of room for added battery power and other options. Just started no video yet.. stress
Looks supercool! Good luck on the progress...