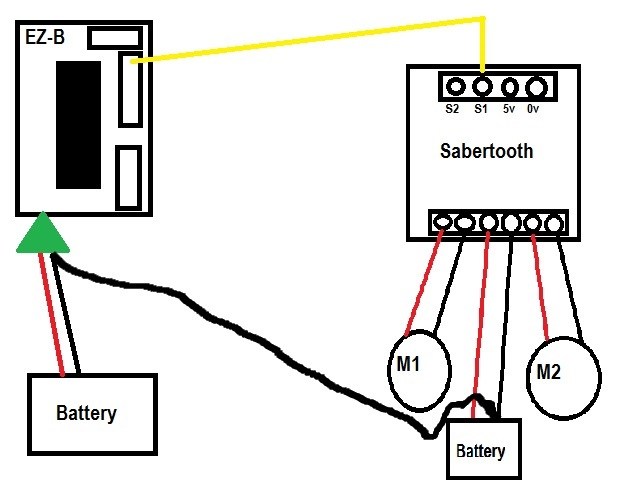
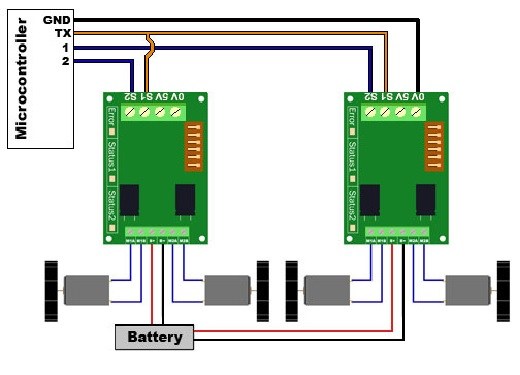
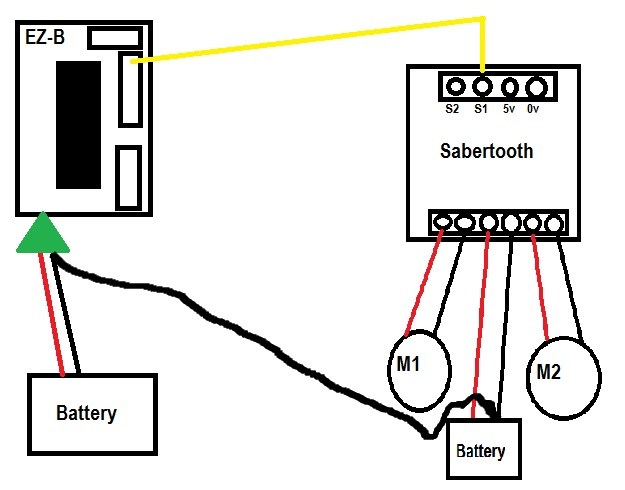
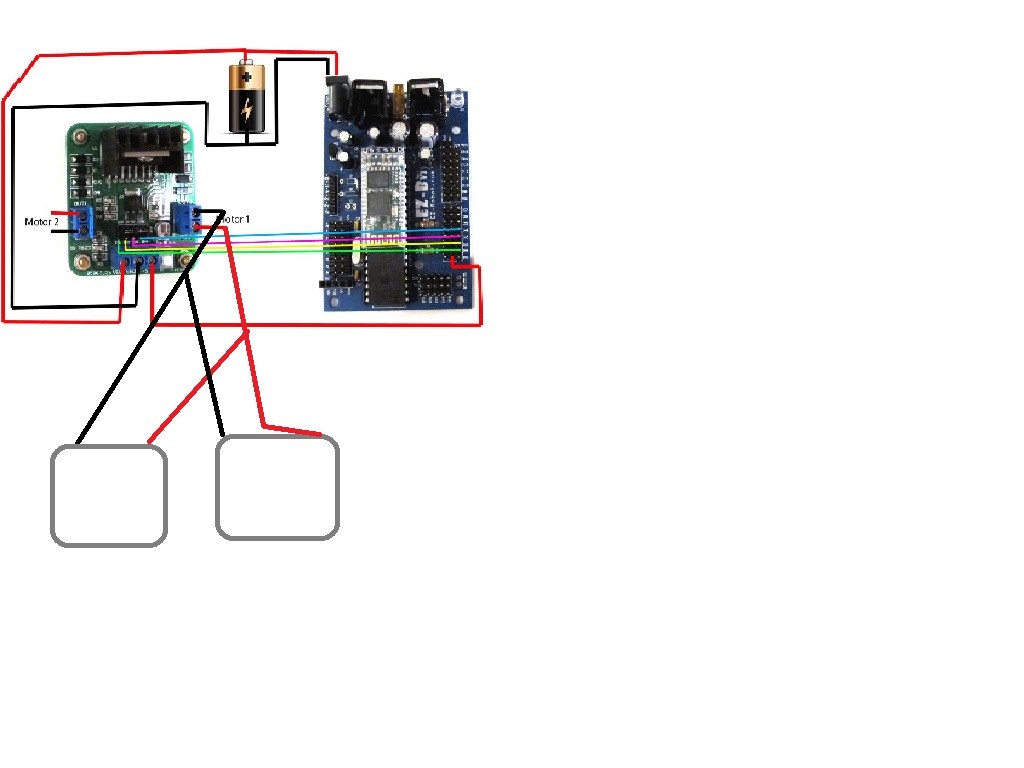
modifying a rc car(truck i guess) to operate off a sabertooth and the ez-b. Any responces are welcome
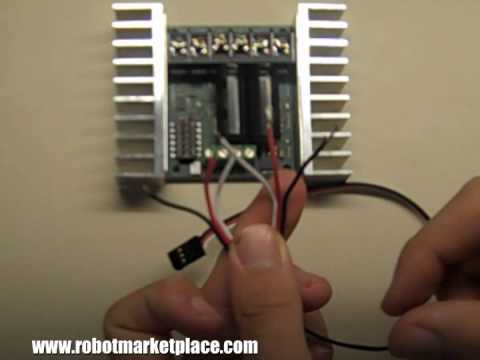
Specs: Sabertooth 2x12 Ez-b V3 2, 2.8-3A dc motors w/6A peak standard servo for steering
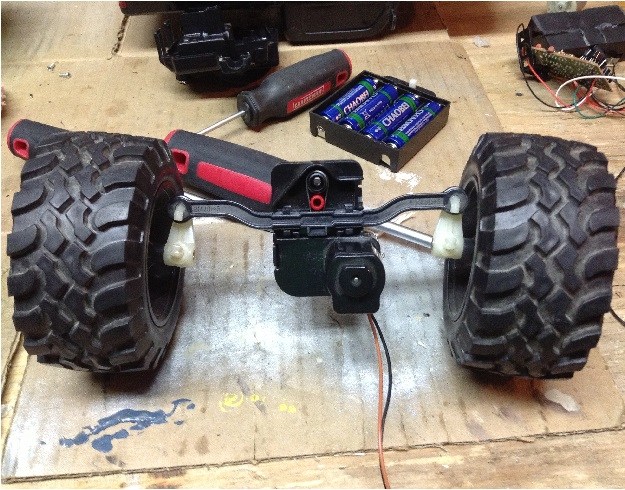
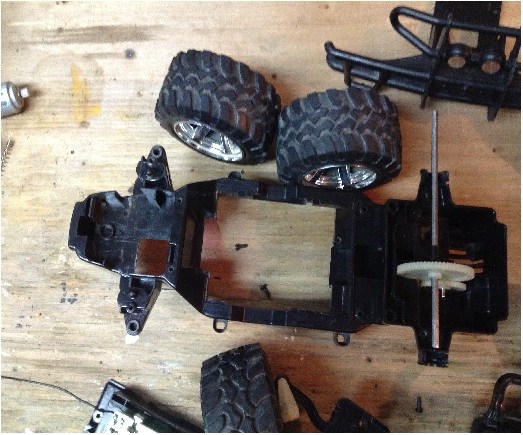
Rc car torn apart:
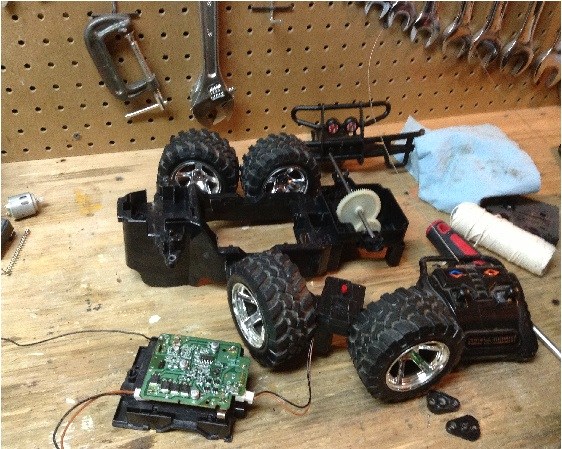
the main body. the wheels were driven by one motor and gears. going to modify and put 2 motors directly(with gearboxes) on the wheels. then attach to the sabertooth and yadi yadi ya.
By CardboardHacker
— Last update


Discover more robots
J's My New Toy I'm Building
Power Wheels converted with a paintball turret on bike forks, actuator for vertical control, drive speed controller and...
Sudo's Shogun V2
Shogun humanoid's redesigned knees reduce bend and boost load capacity; EZ-B and camera repainted; ready for walking and...
Cobra71's Beginner Starts With Dickeys Rolling Olli
Build a Rolling Olli robot with Synthiam ARC and EZ-B for Xbox360 pad control, autonomous driving, pan/tilt camera,...

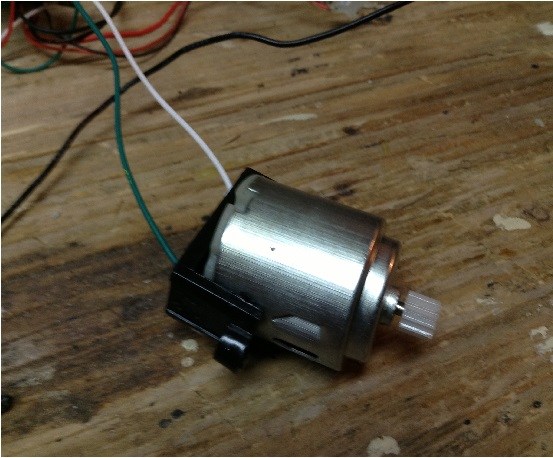
1 of two motors without gear box.
and steering which will be heavily moded. by the way, does anyone have a script that will let you control the servo and when you let go it will move back to centre? going to use custom movement panel.
need a command that will cue the sabertooth forward and reverse in the custom movement panel.
will the Forward() command cue the sabertooth motors forward?
K so recap:
1:Need a command that will cue the sabertooth forward and reverse in the custom movement panel. Will the Forward() command cue the sabertooth motors forward and reverse() cue the sabertooth reverse, without sabertooth movement panel? or do i require a sabertooth m.p.?
2:how can i block the sabertooths ability to turn the wheels different ways? Thinking i will try setting the left turn and right turn values to 0. will this work?
Any responces will be great.
Modified the chassis to fit the motors.
The motors and their gear boxes are in place.
This is cool! Nice re-use of parts.