
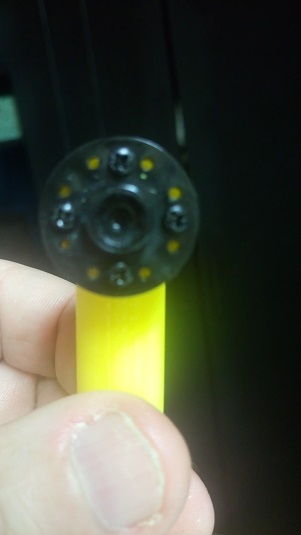
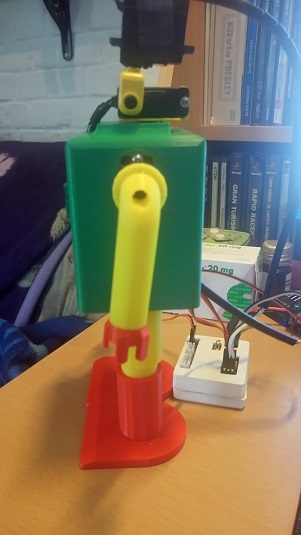
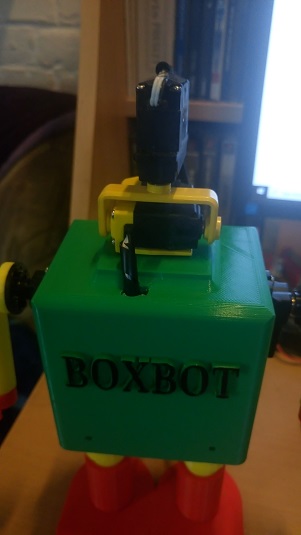
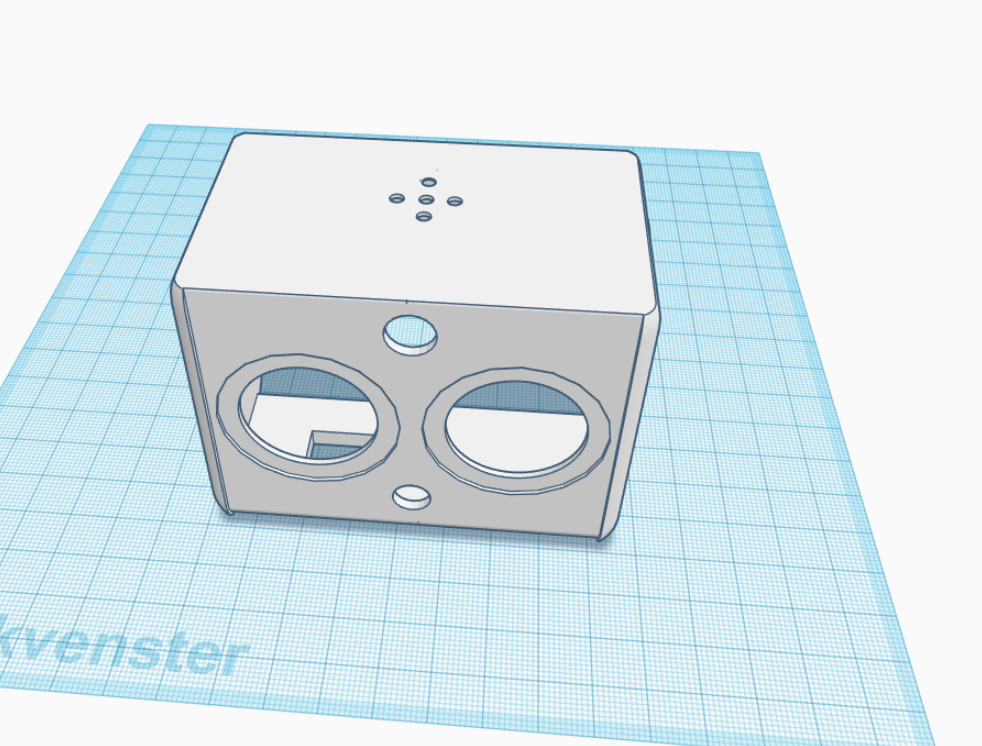

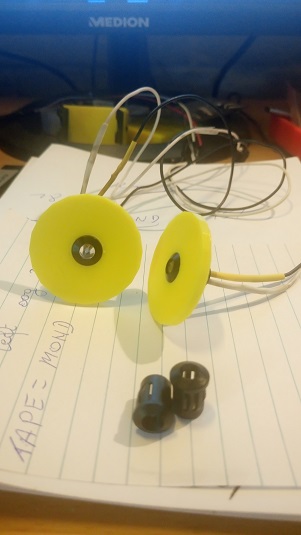
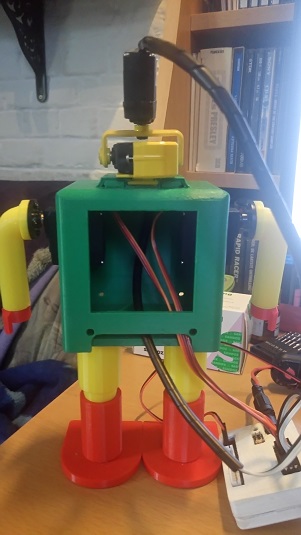
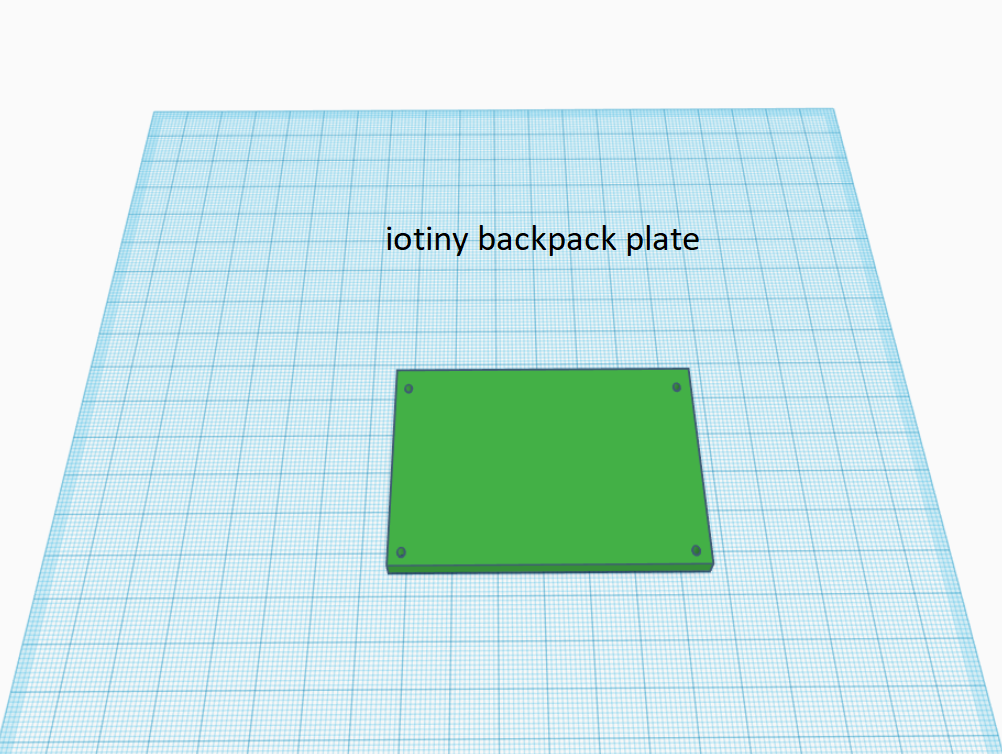
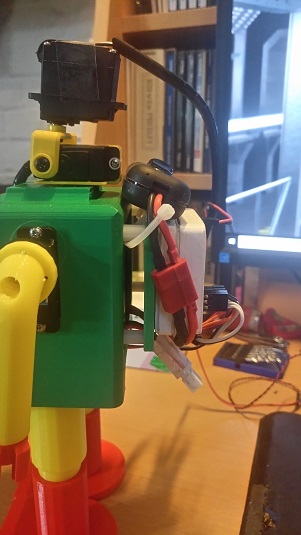
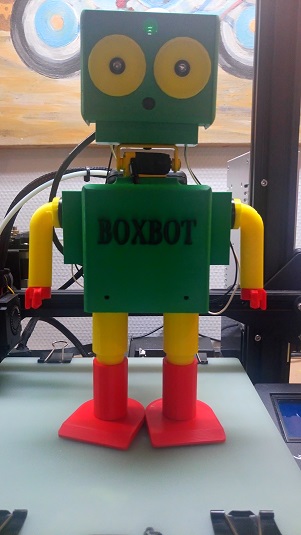
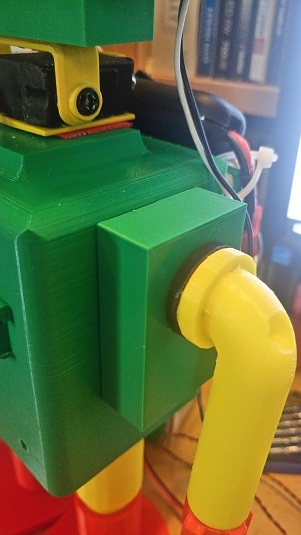
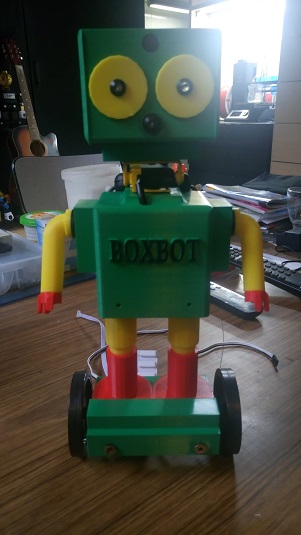
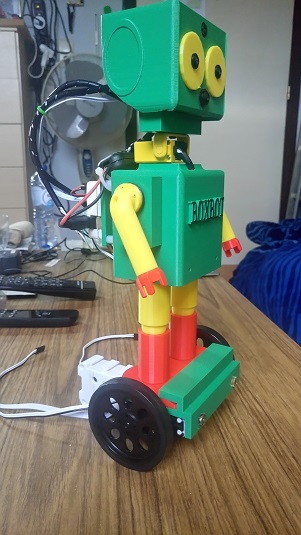
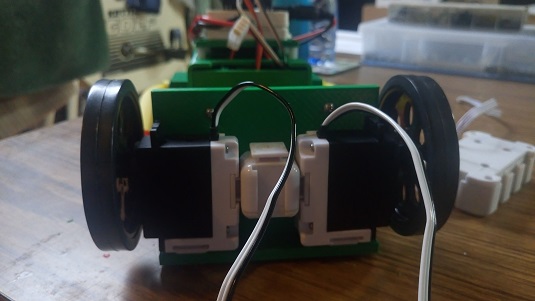
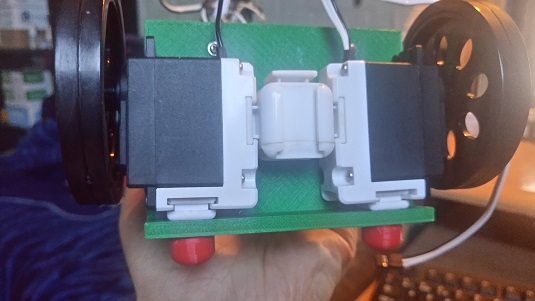
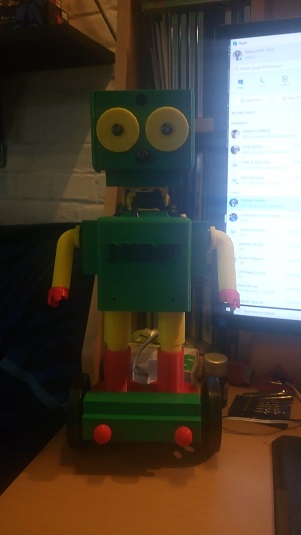
P2 stands for printed second version boxbot.cause dj made the first boxbot. the V1 stands for version 1.version V2 will get some wheels. this robot is a desk robot to train excample camera /position movements and more. it has 4 micro servo's camera still to come ,two flat eye LED blue. the red covers lowerlegs are changeble i, other colors. still need to do .head to print/camera /choulder covers (servo's )
By Nomad 6R
— Last update

Discover more robots
Cardboardhacker's Alex Cardboard Omnibot Twin
Build ALeX humanoid robot - 4.5ft, lightweight frame using servos, ez-B camera, 12V motors/battery, recycled materials...
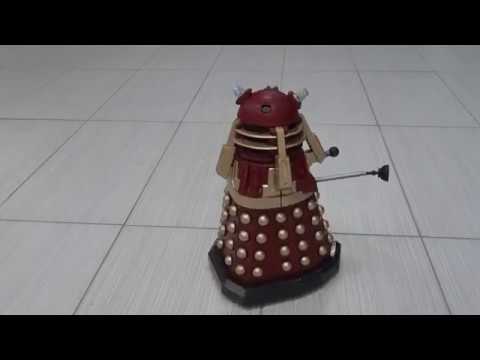
DJ's Ez-B V4 Dalek
Control a Dalek EZ-Robot upgraded to EZ-B v4 with added servos for nose, ray gun and torso plungers via Synthiam...

Orwnic82's Ez-B Processor Quadrotor
Control a DIY quadrotor with Visual Studio apps: blade/angle monitoring, individual motor control, tilt monitoring and...

here's a little video.
Nice eye lights, good movements - Almost a JD robot
He he walk yet?
EzAng
he wil get wheel base.
I used the servo City Prowler Robot Kit
Check these: https://www.servocity.com/kits/robot-kits
Also the Actobotics Attachment Ideas are great to look at:
https://www.servocity.com/actobotics-attachment-ideas/
EzAng
wow these are awesome wheels.thanks for the links. haha funny there is one with my name,NOMAD . nomad wheels
lol yes that is funny nice wheels
Hi Nomand, That head came out great. Cant wait to see the wheel base you choose
hey robohappy
sorry for late respons.i was also thinking off using the two balance board, and some ez wheel servo's.