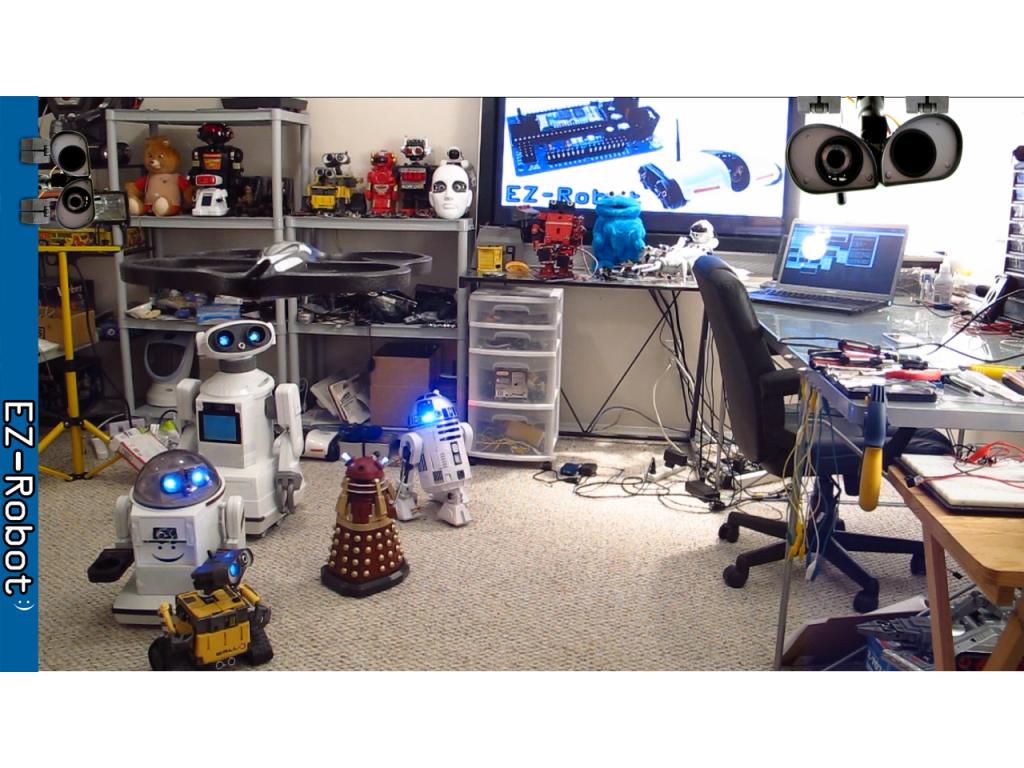
Demonstration how I controlled 6 robots with one joystick in my Pecha Kucha presentation. In this video, I use an Omnibot, Omnibot 2000, Wall-e, Dalek, R2D2 and a flying AR Parrot Drone.
All robots are fitted with an EZ-B Robot Controller and connected to the ARC Robot Control Software. The software will allow up to 5 EZ-B Controllers at one time.
To control the movement from each robot, a movement script was used with respective scripts per movement direction (forward, left, right, reverse, stop).
To synchronize the head servos, the Relative servo control was used. Each robot head servo was related to 2 master servos (horizontal and vertical). The ratio for the relative servos was set to 1:1.
By DJ Sures
— Last update


Discover more robots
Faengelm's Roli The Climber
HDD servo-powered arms and legs let the Roli Rover climb obstacles; simple script controls movement and servo...
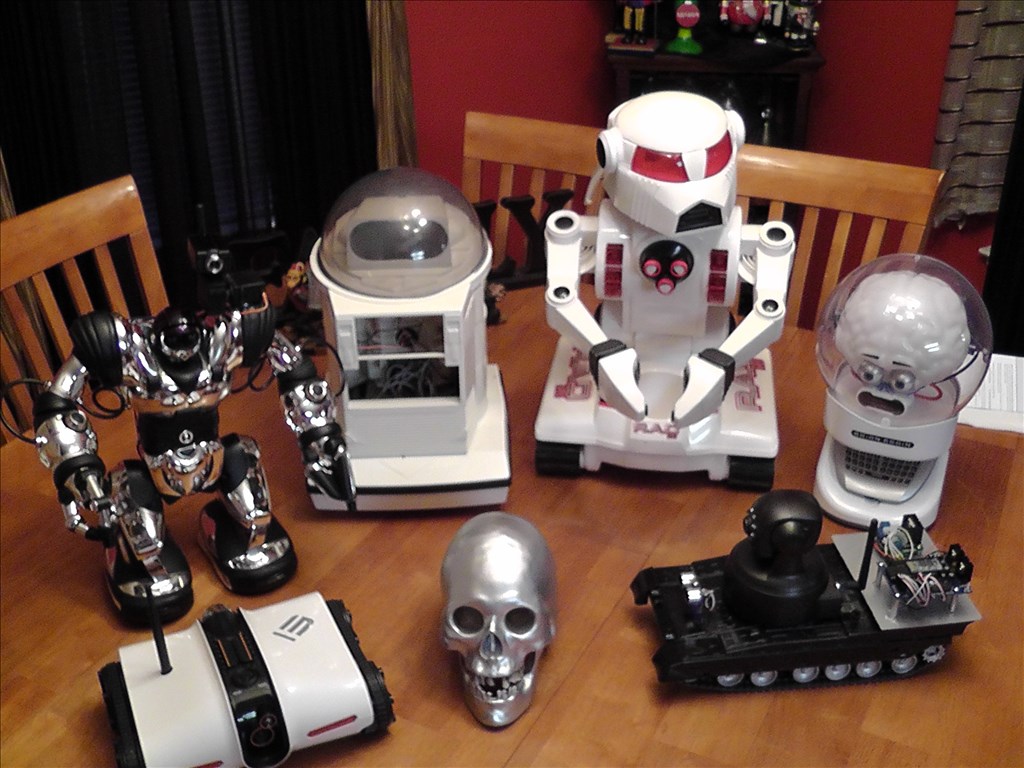
Joseph4760's Project X-Men
Project X-Men: EZ-Robot custom builds, modified tank with IP camera and sensors, Brookstone Rover, RAD 2.0, Ghost Rider...
J's My Hexapod Project
Modular aluminum robot brackets and hardware for versatile robot builds, torchmate-cut parts, bearings, shoulder bolts,...

I love the way R2 looks the wrong way )
Even now, over a decade later, this is still impressive.