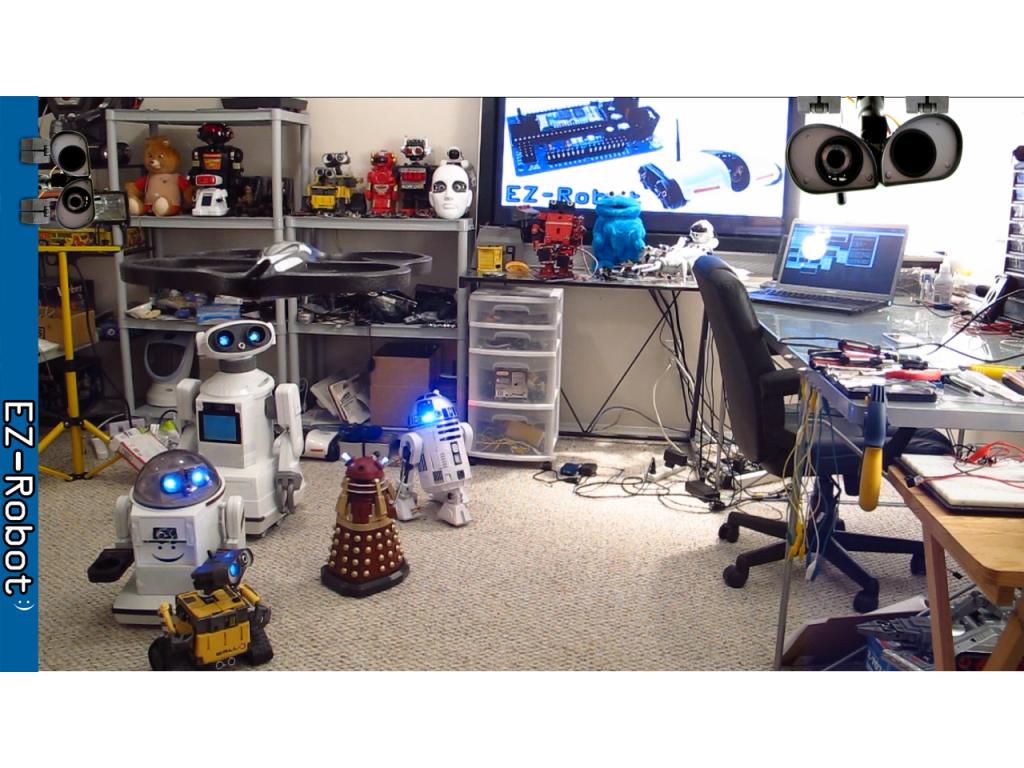
Demonstration how I controlled 6 robots with one joystick in my Pecha Kucha presentation. In this video, I use an Omnibot, Omnibot 2000, Wall-e, Dalek, R2D2 and a flying AR Parrot Drone.
All robots are fitted with an EZ-B Robot Controller and connected to the ARC Robot Control Software. The software will allow up to 5 EZ-B Controllers at one time.
To control the movement from each robot, a movement script was used with respective scripts per movement direction (forward, left, right, reverse, stop).
To synchronize the head servos, the Relative servo control was used. Each robot head servo was related to 2 master servos (horizontal and vertical). The ratio for the relative servos was set to 1:1.
By DJ Sures
— Last update


Discover more robots
Waynea's Tall Tower Light Controller - Ezb V4
Monitor 19 broadcast tower strobe lights remotely with EZ-B v4-easy relay integration, fault signaling and simple alerts...
Luis's I2c Ezb Arduino1 Sensor
Use an Arduino as an I2C sensor controller for EZB3/4 to read PING ultrasonics via Ez-Builder with simple Arduino and...
Dave's Hello All
Control Johnny 5 replica with EZ-B controller - easy starting point for testing and learning robot control and...

I love the way R2 looks the wrong way )
Even now, over a decade later, this is still impressive.