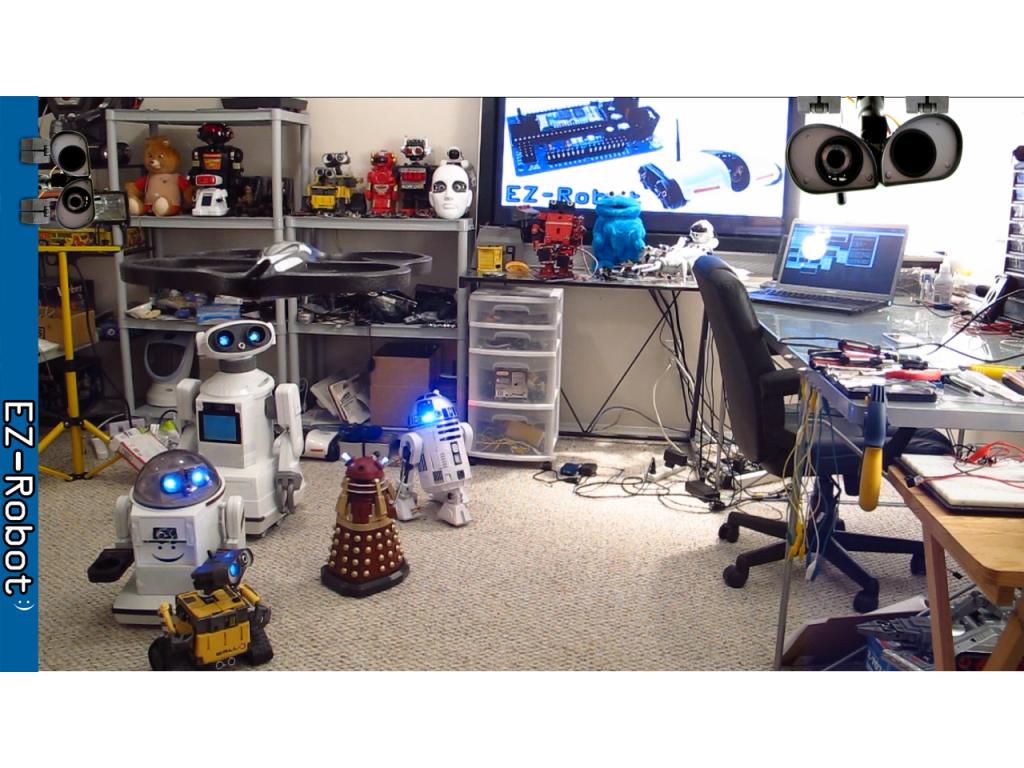
Demonstration how I controlled 6 robots with one joystick in my Pecha Kucha presentation. In this video, I use an Omnibot, Omnibot 2000, Wall-e, Dalek, R2D2 and a flying AR Parrot Drone.
All robots are fitted with an EZ-B Robot Controller and connected to the ARC Robot Control Software. The software will allow up to 5 EZ-B Controllers at one time.
To control the movement from each robot, a movement script was used with respective scripts per movement direction (forward, left, right, reverse, stop).
To synchronize the head servos, the Relative servo control was used. Each robot head servo was related to 2 master servos (horizontal and vertical). The ratio for the relative servos was set to 1:1.
By DJ Sures
— Last update


Discover more robots
DJ's JD Humanoid Puppet
Sync two JD robots' servos in real time with a Synthiam ARC script using PWM Servo Feedback to mirror positions over...
DJ's Self Docking Robot
Synthiam ARC enables phone control and simple self-docking for Ohmnilabs telepresence robots using a Logitech camera...
Ezang's My New Adventruebot Robot
New Adventure Bot: a first look at a personal robotics project and the creator's initial attempt.

I love the way R2 looks the wrong way )
Even now, over a decade later, this is still impressive.