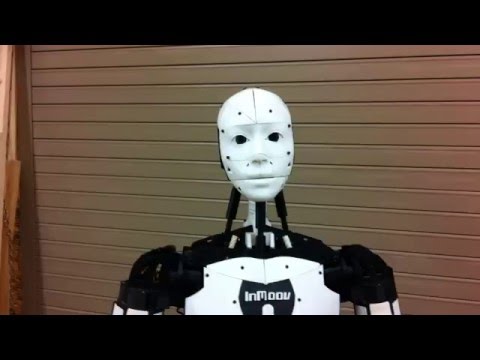

I redesigned the Top Stomach Pistons for quicker movement. The STL files are on Thingiverse. https://www.thingiverse.com/thing:1047605
By bhouston
— Last update

Discover more robots
Tmesserschmidt's Topsie The Easy To Build Robot Dog
Build Topsie, a low-cost DIY quadruped-no 3D printing or soldering; assemble in a week and program walking gaits with...
Charleybot's Project Multi-Omnibots 2000
Upgrade Omnibot 2000s with Mini-ITX PCs, 12V battery power, servo-replaced arms, L298 motor controllers, USB Lifecam...
Robotz012248's My Desktop Trio Of Robots
Interactive desktop robots built from a Harbor Freight parts box using EZ-B, micro servos, pan/tilt and LEDs, programmed...

Excellent work Bob, as always. The video looks great!
I actually used one of your stomach pinion gears modifications in my InMoov for the elbow joints, without having to modify the servo and setup the external pot for the elbow joint. It works pretty well, you do lose some slight moment, when you move the elbow to 90 deg, but not much.
Keep up the modifications.
Cheers, Chris.
Wow, cool Bob. Pretty soon he'll be able to dance the Hoky Poky!
Nice work Bob!
Thanks for the nice comments everyone. @cem, I hadn't thought of using those pistons in the biceps, I might change mine too. You do lose some torque with them but you gain speed. And DJ, yes, legs are on the drawing board.
Bob, Your improvements are amazing!
The parts for this latest modification are now on Thingiverse. https://www.thingiverse.com/thing:1409964
Have fun!
@Bob, sweet! Thanks Bob, getting them now. I will let you know how it comes out in a couple of weeks.
I modified the main socket for this stomach modification. It's now a 2 part socket that holds the joint together better when it is moved to it limits or lifted on. The STL's are here; https://www.thingiverse.com/thing:1409964