
cE9s4PsOgeBQIORwjd5!~~60_1-634818020230156250.jpg)



Lupuc4g~~60_35-634706297915000000.jpg)


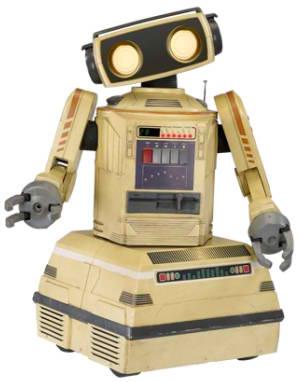
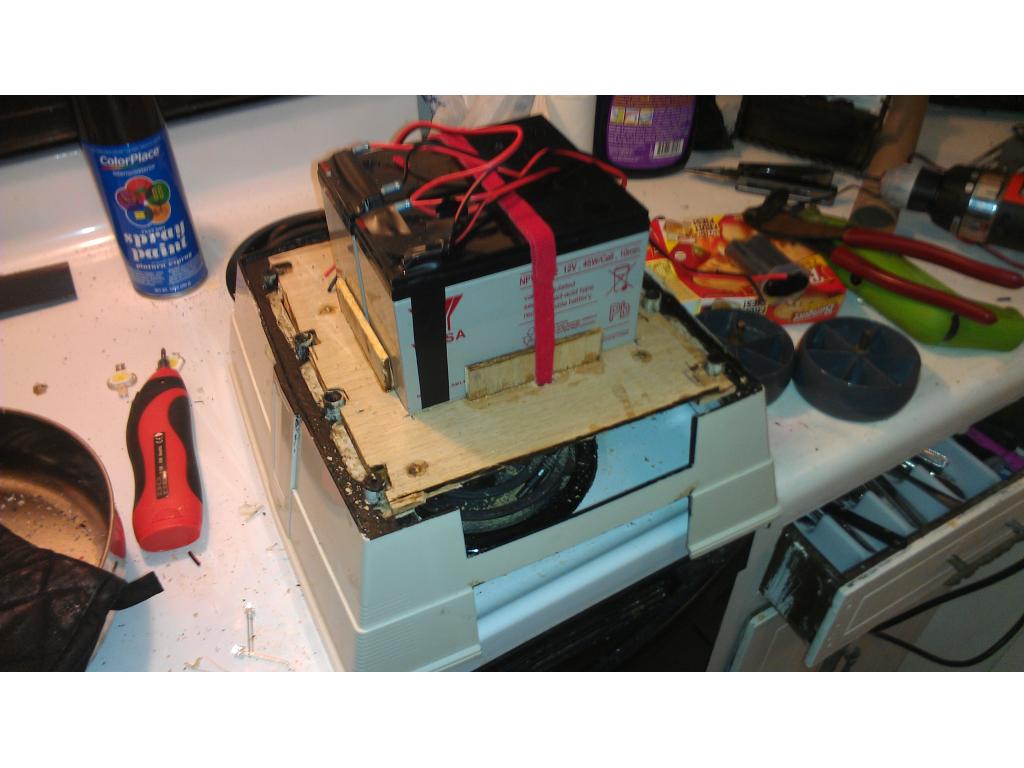

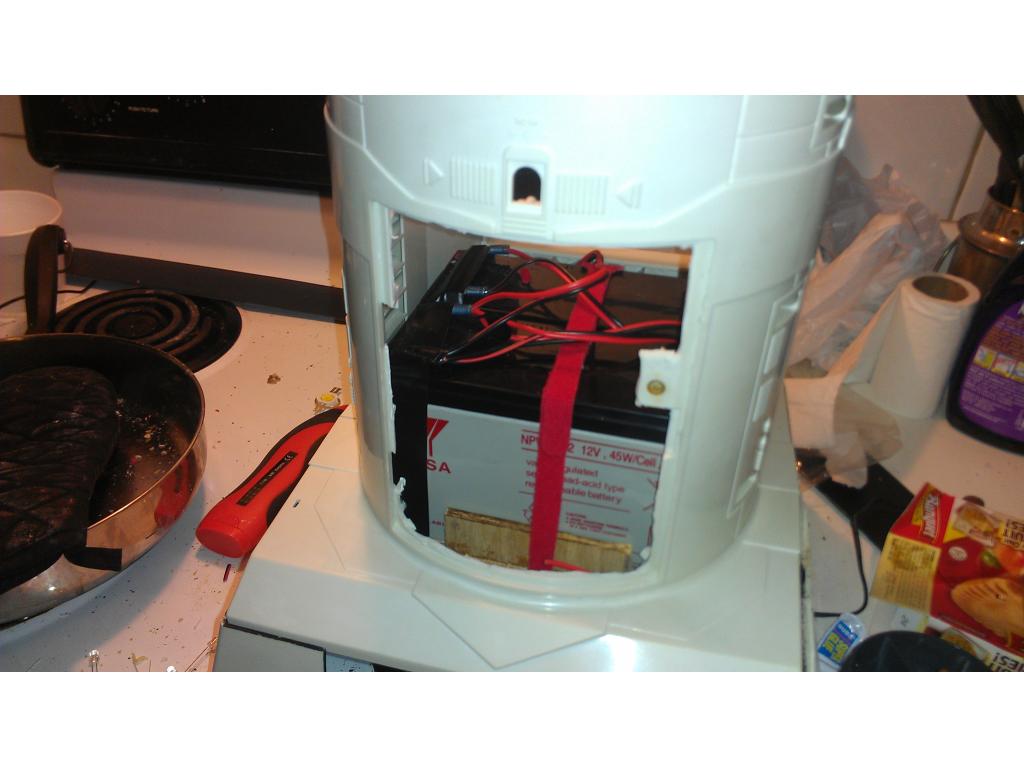
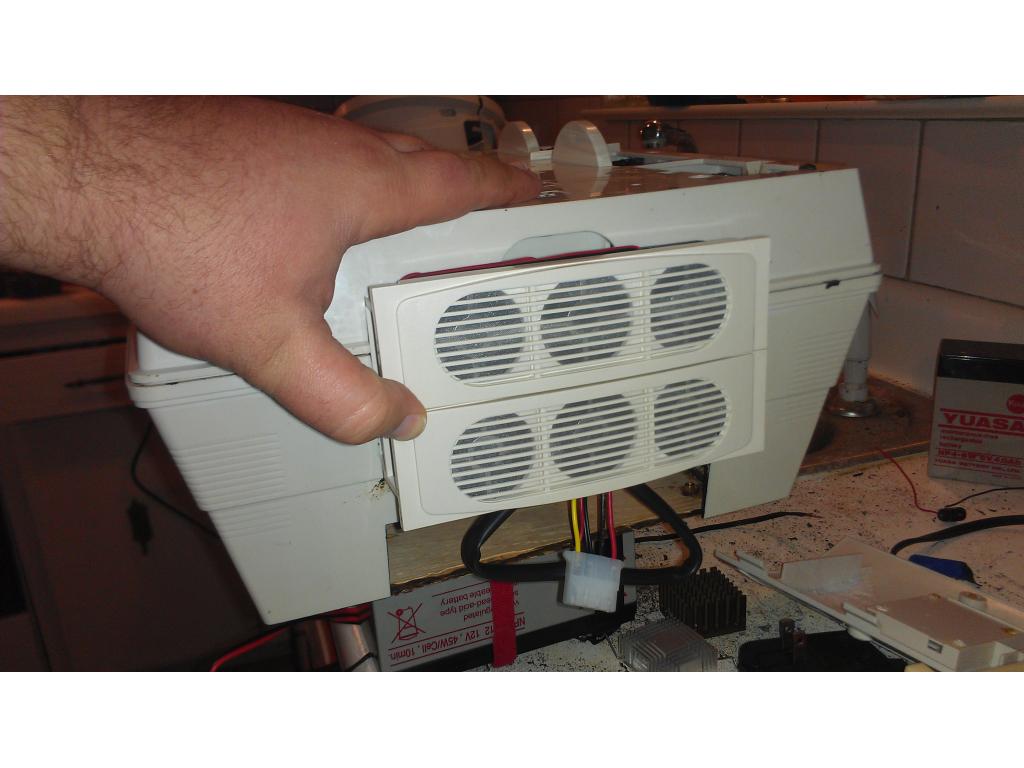
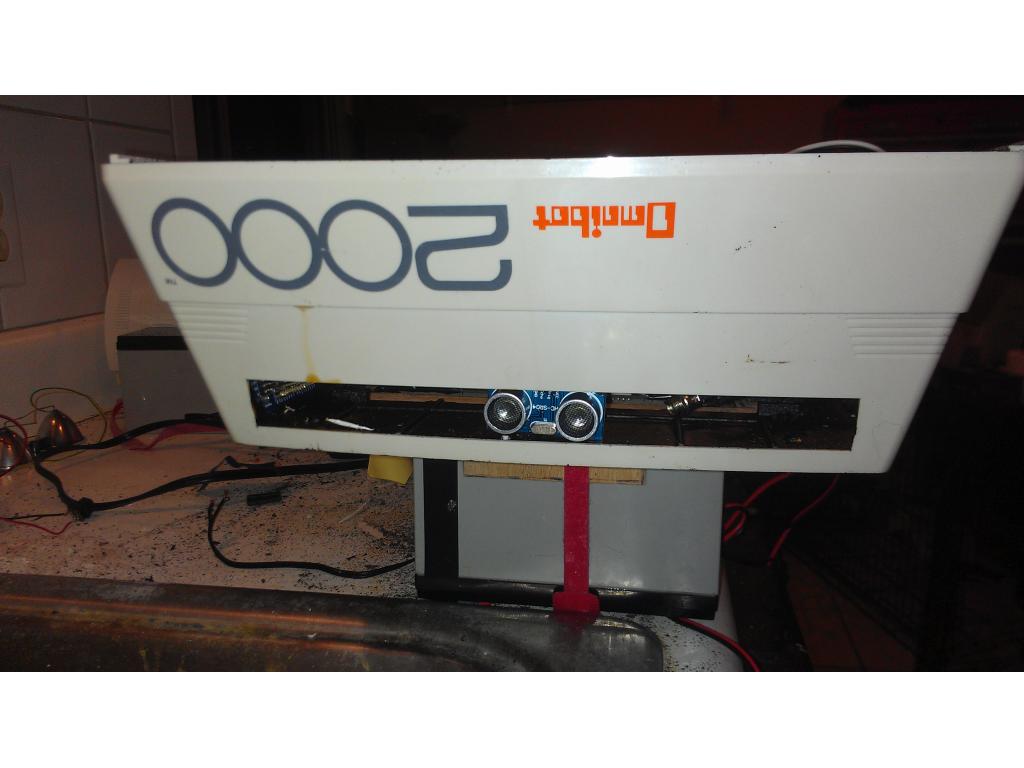
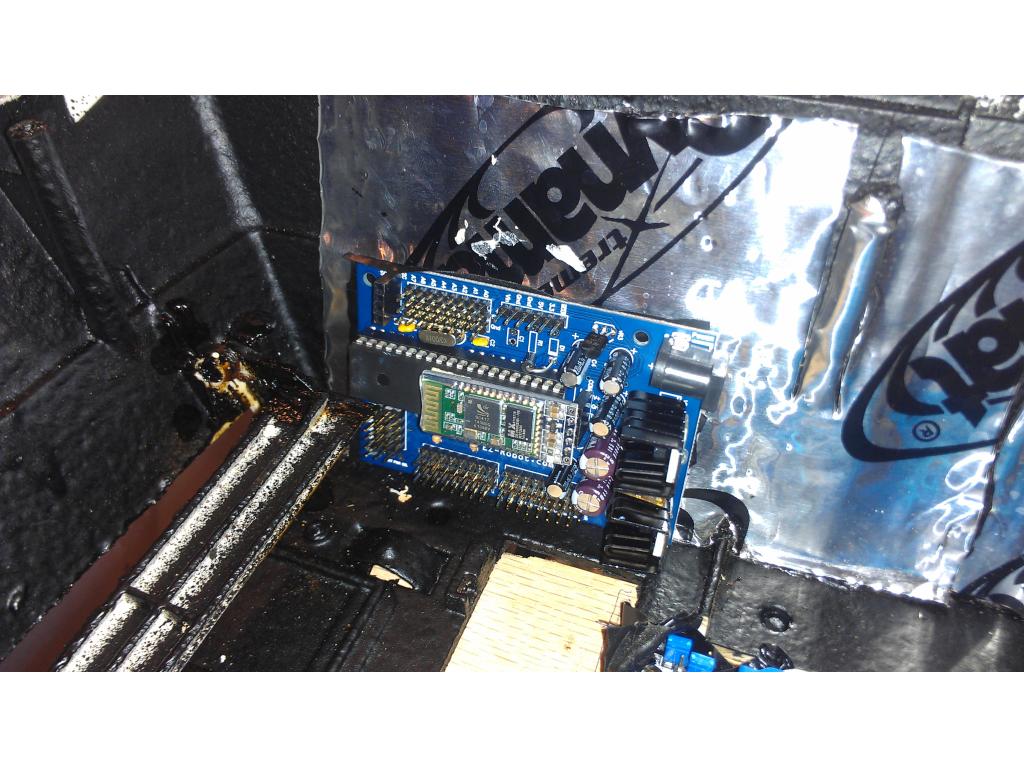
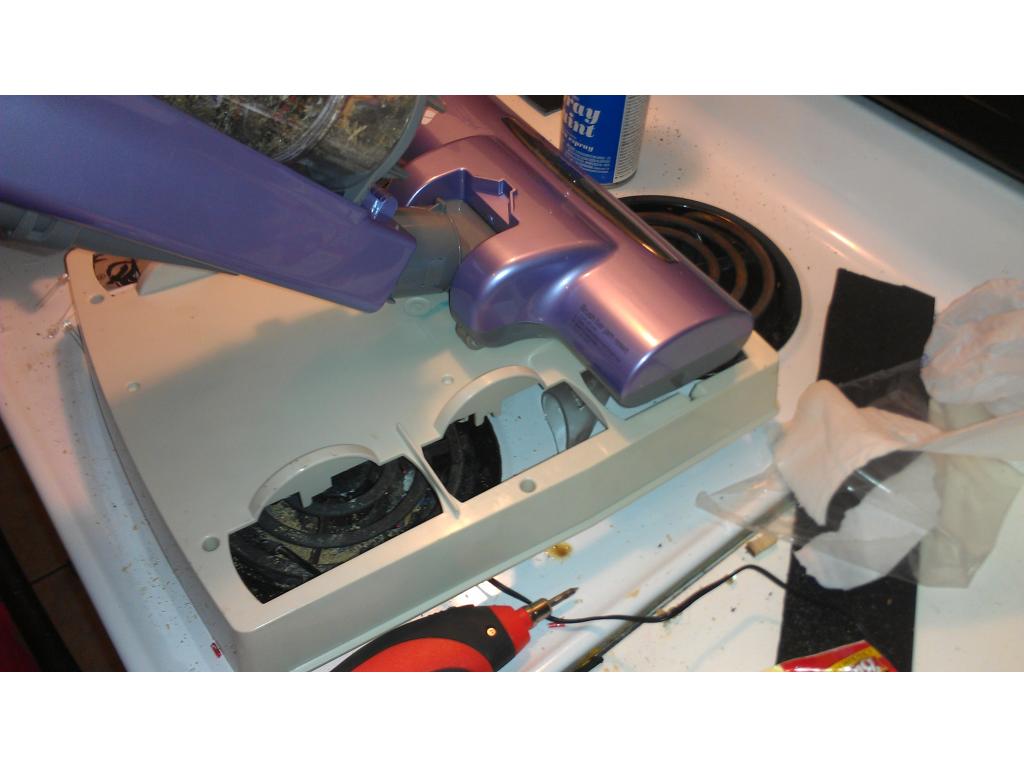

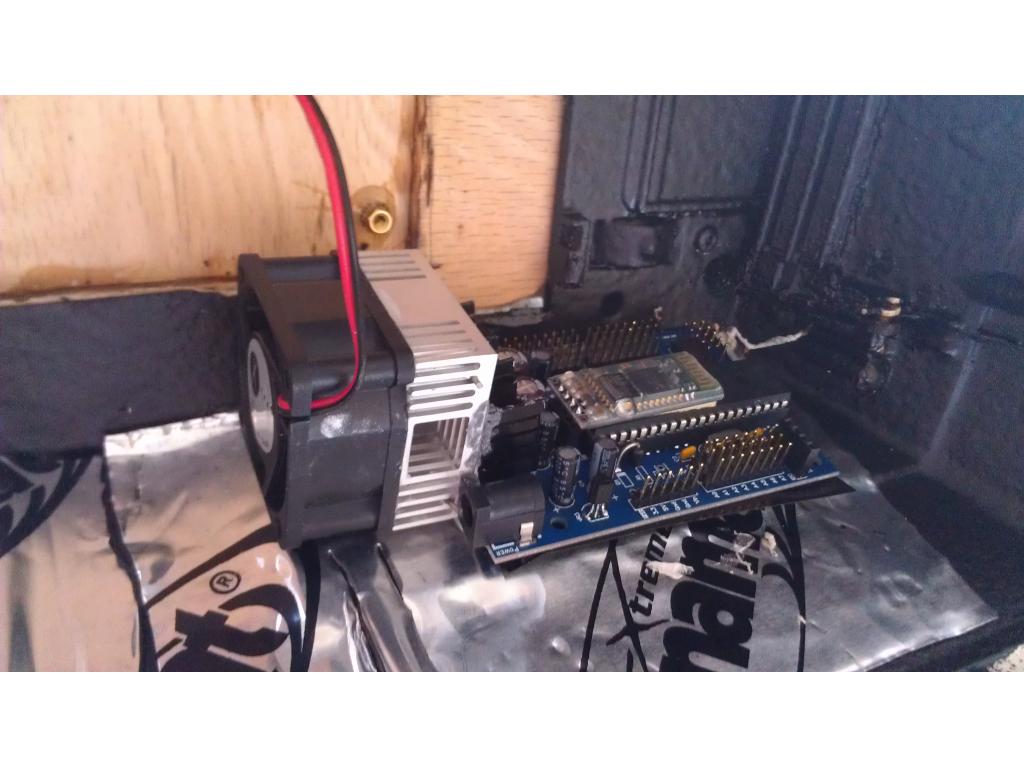
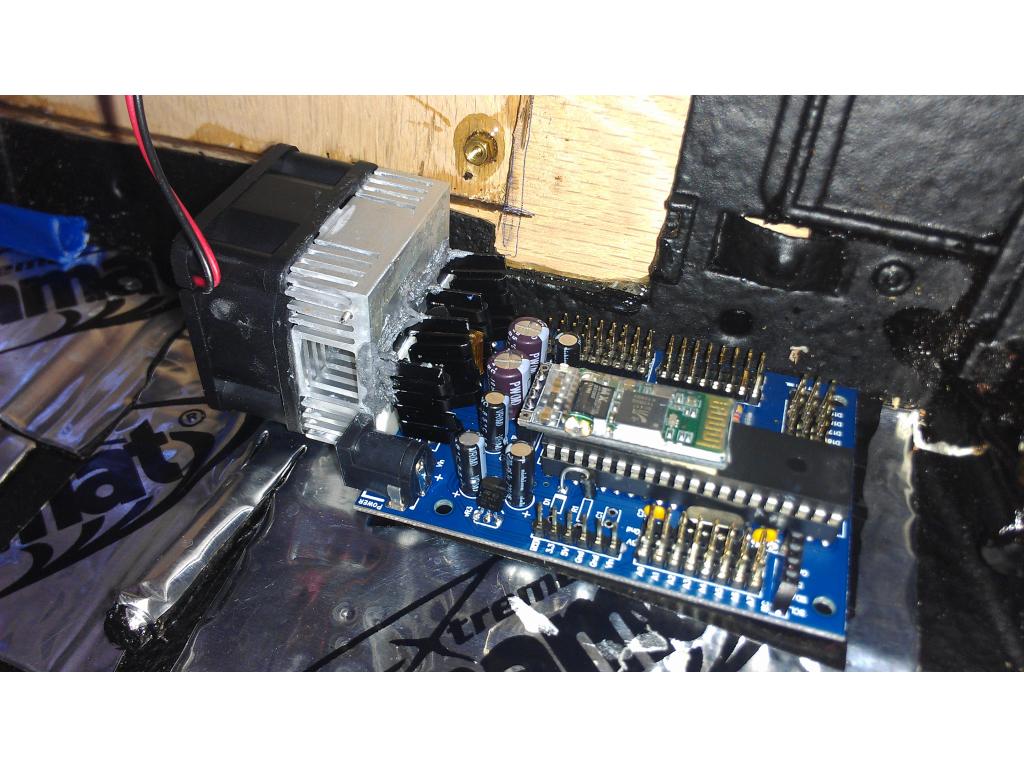

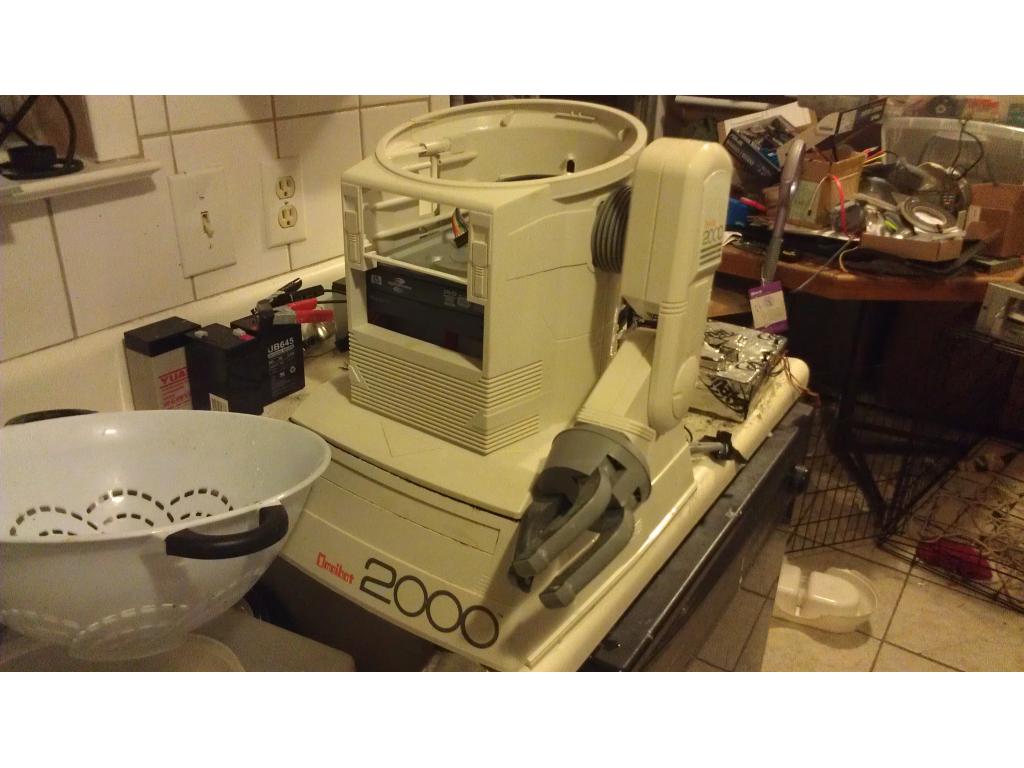
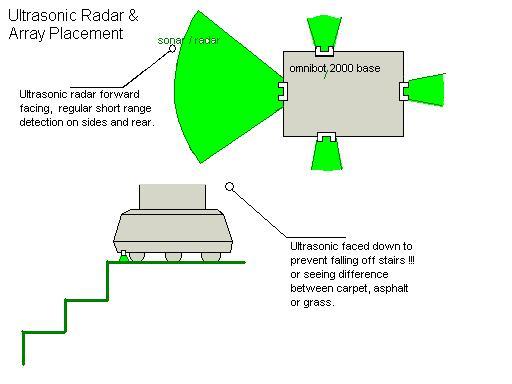
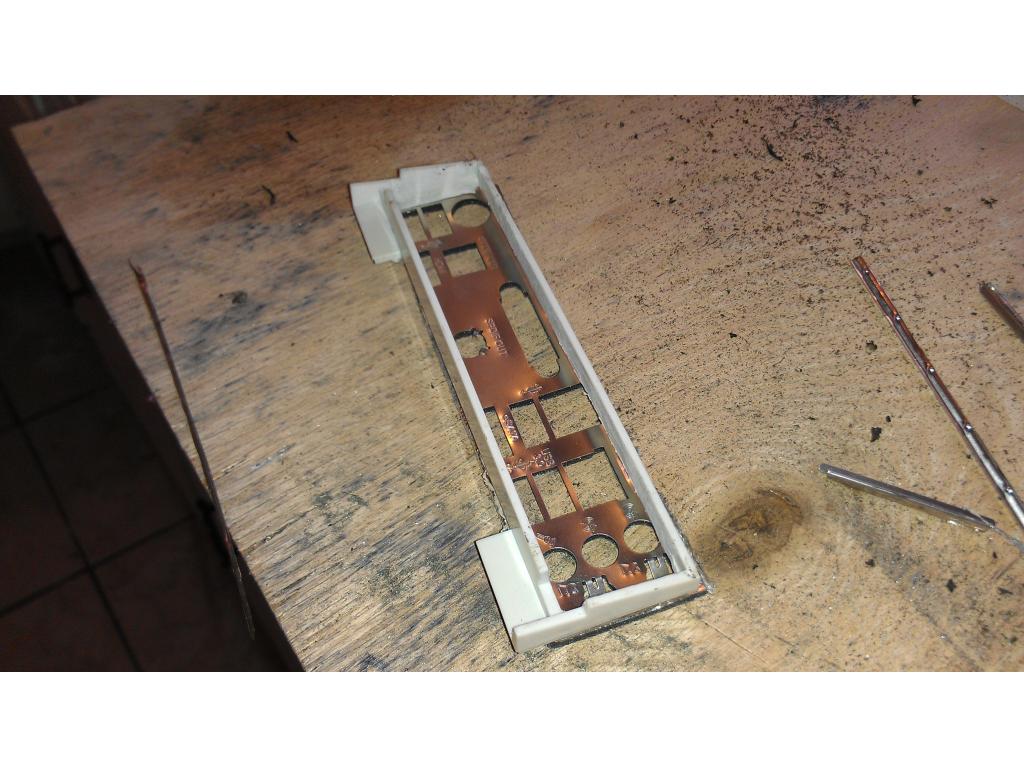
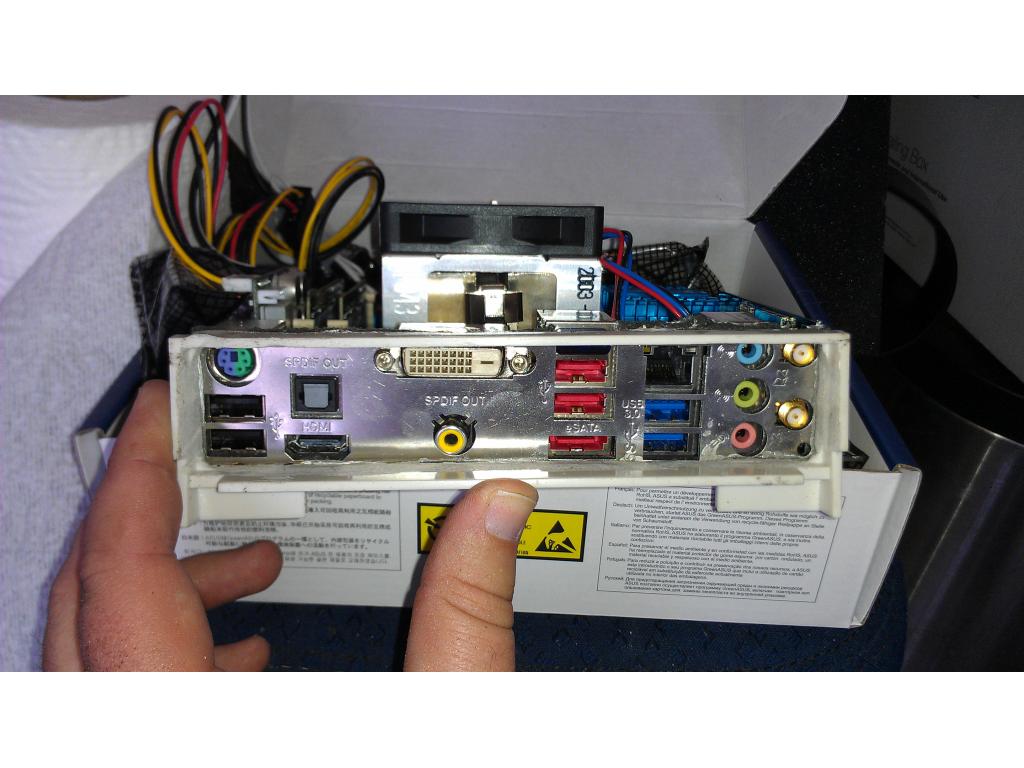
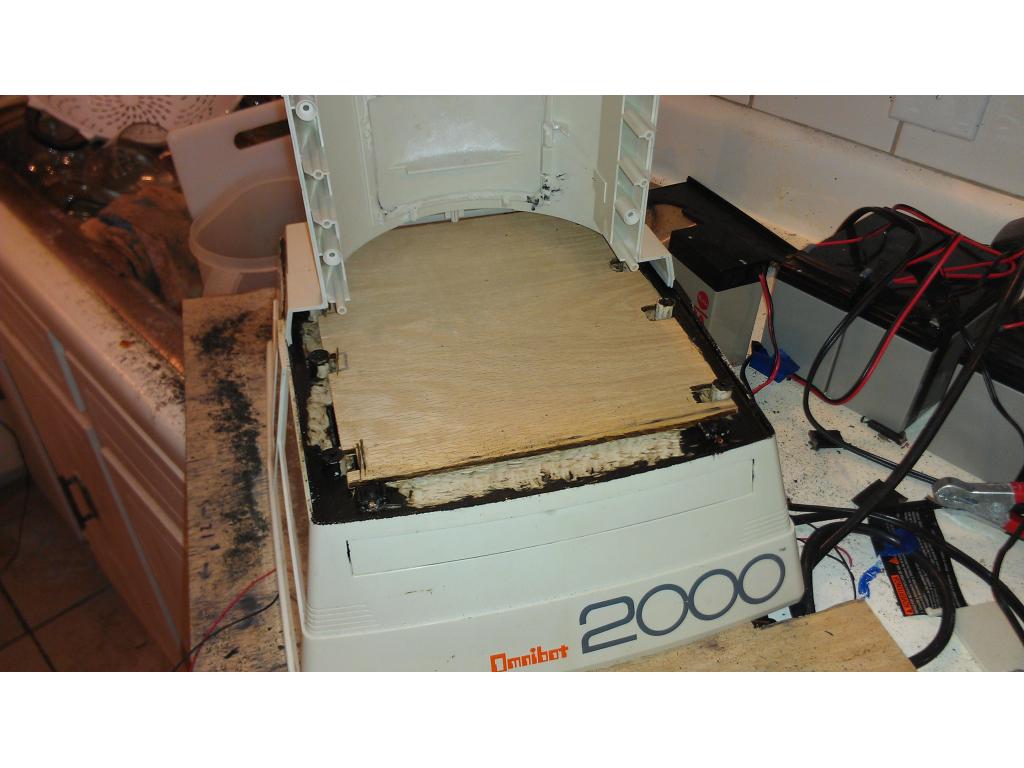
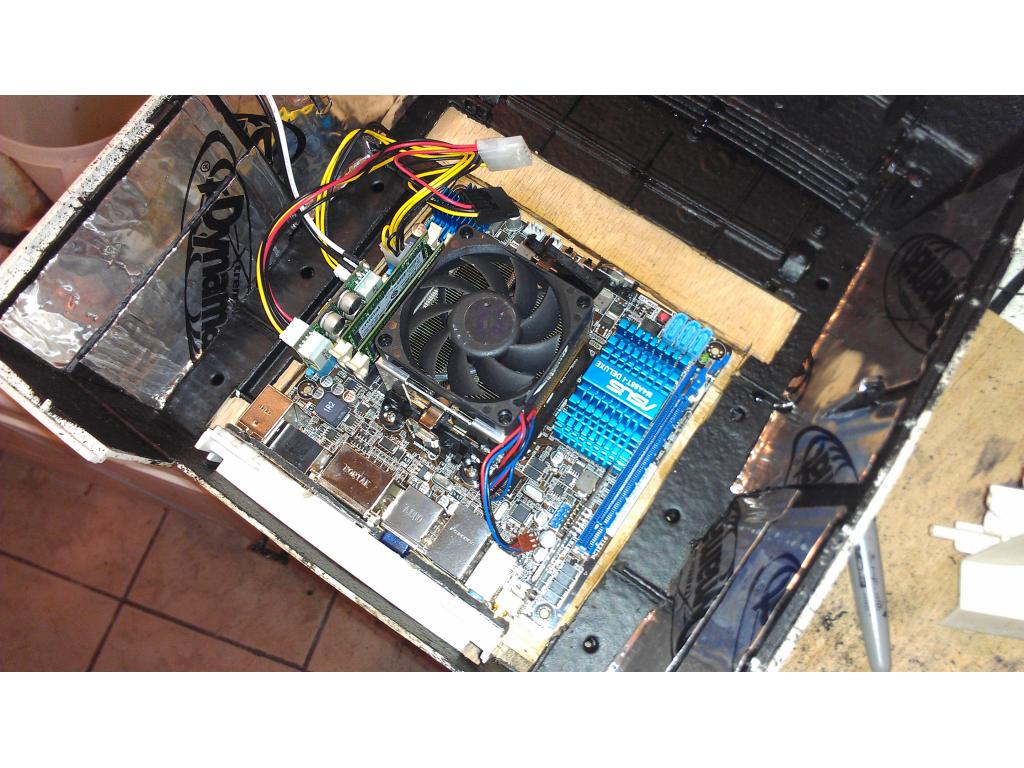
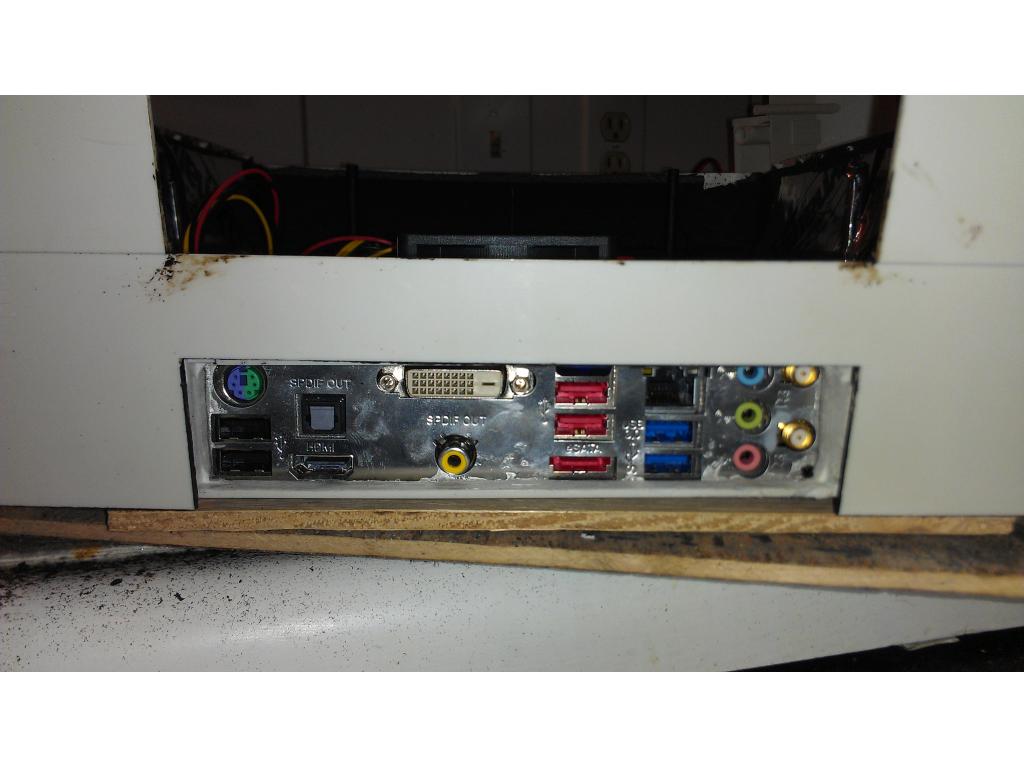
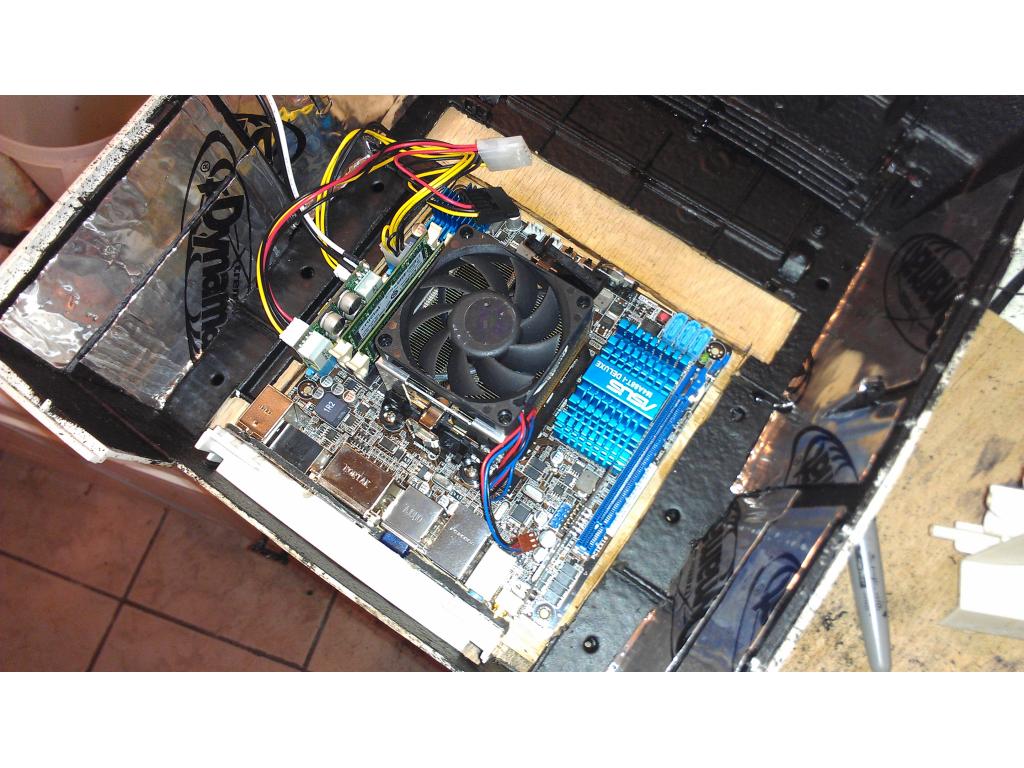
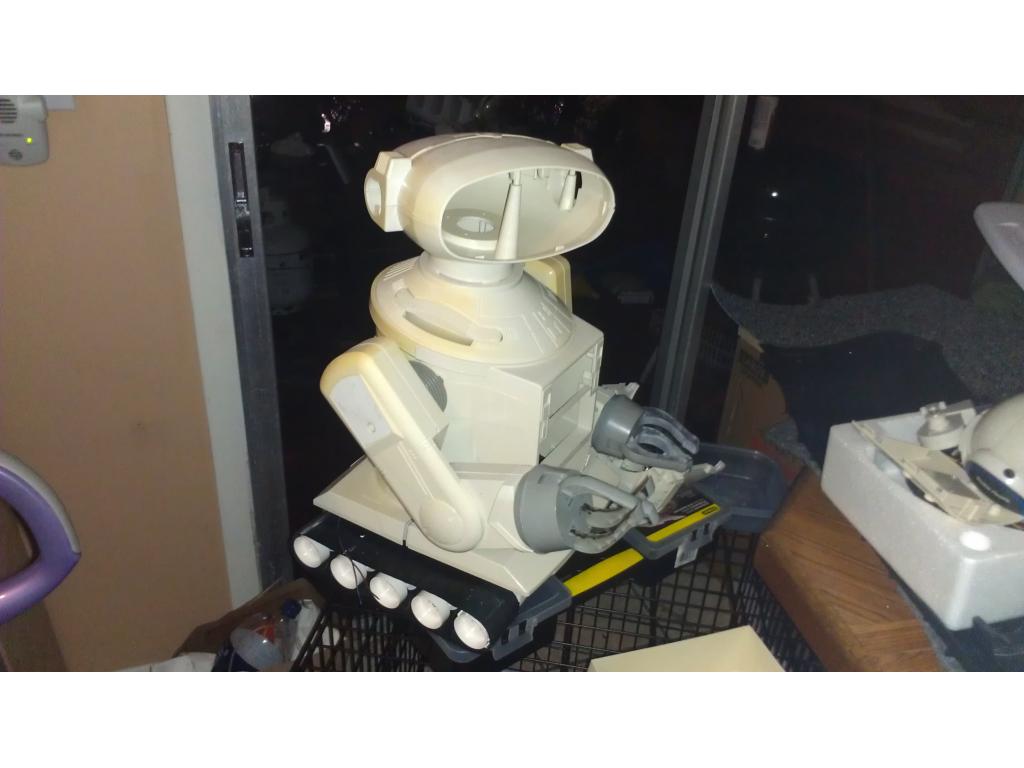
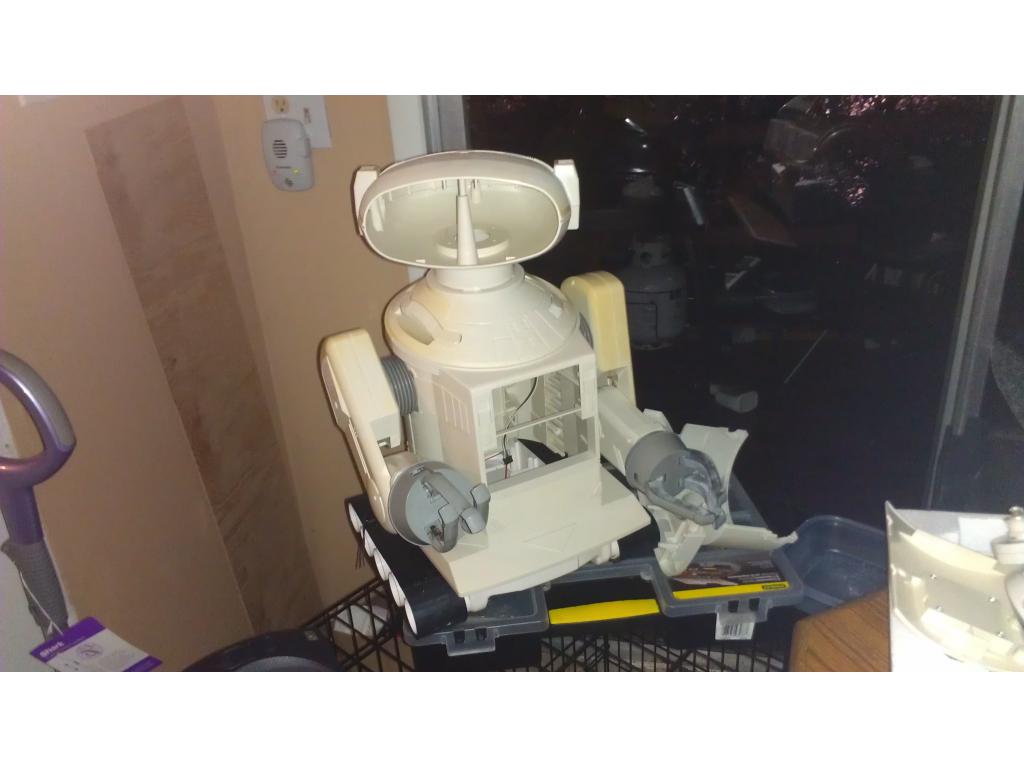
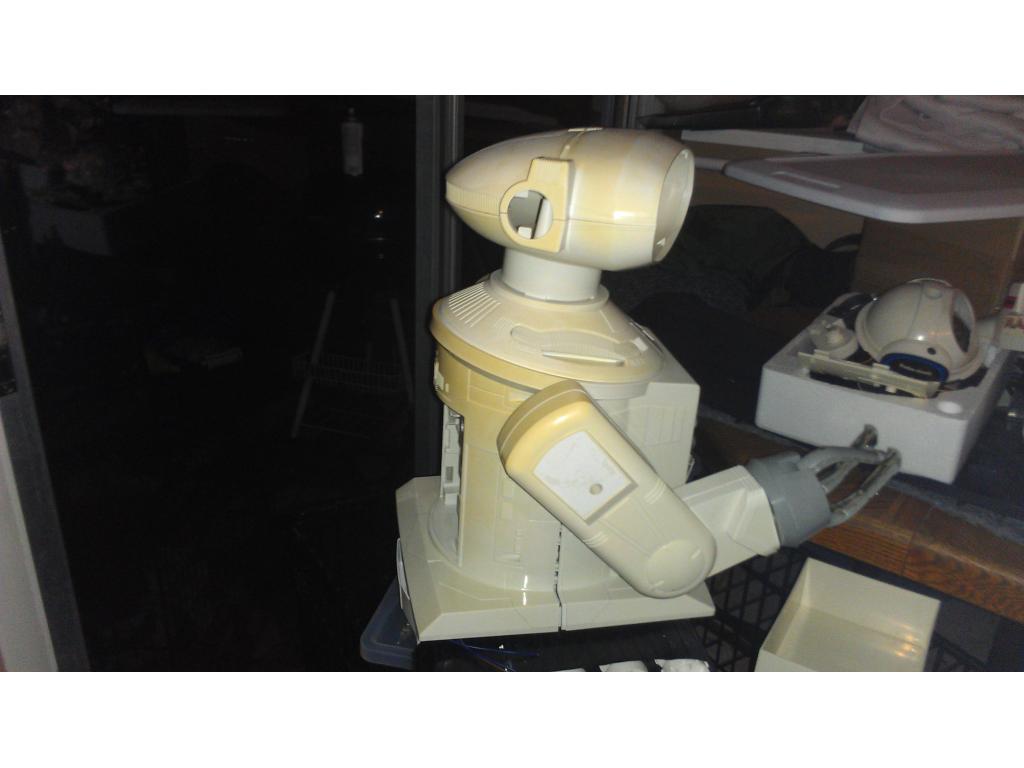
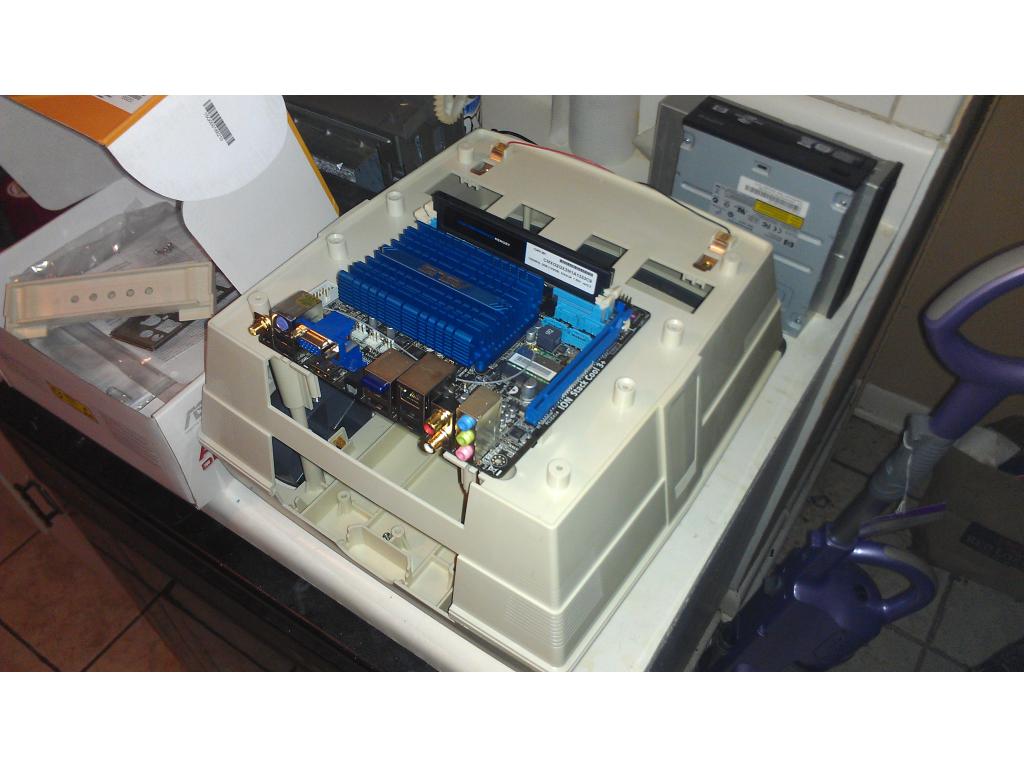
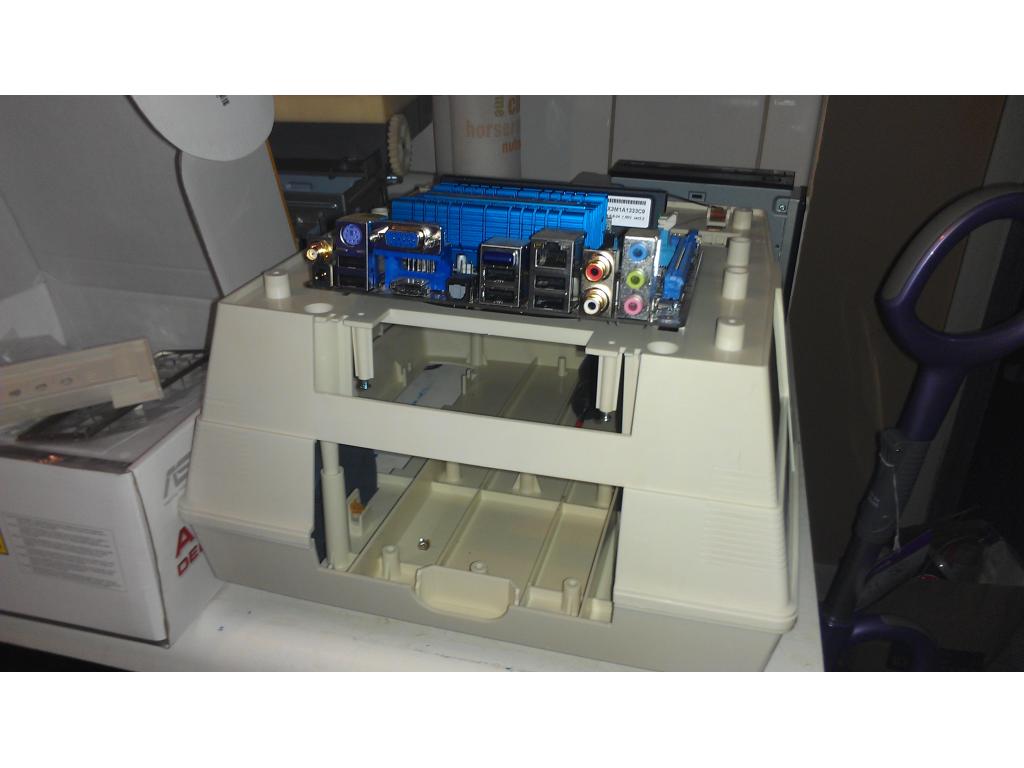
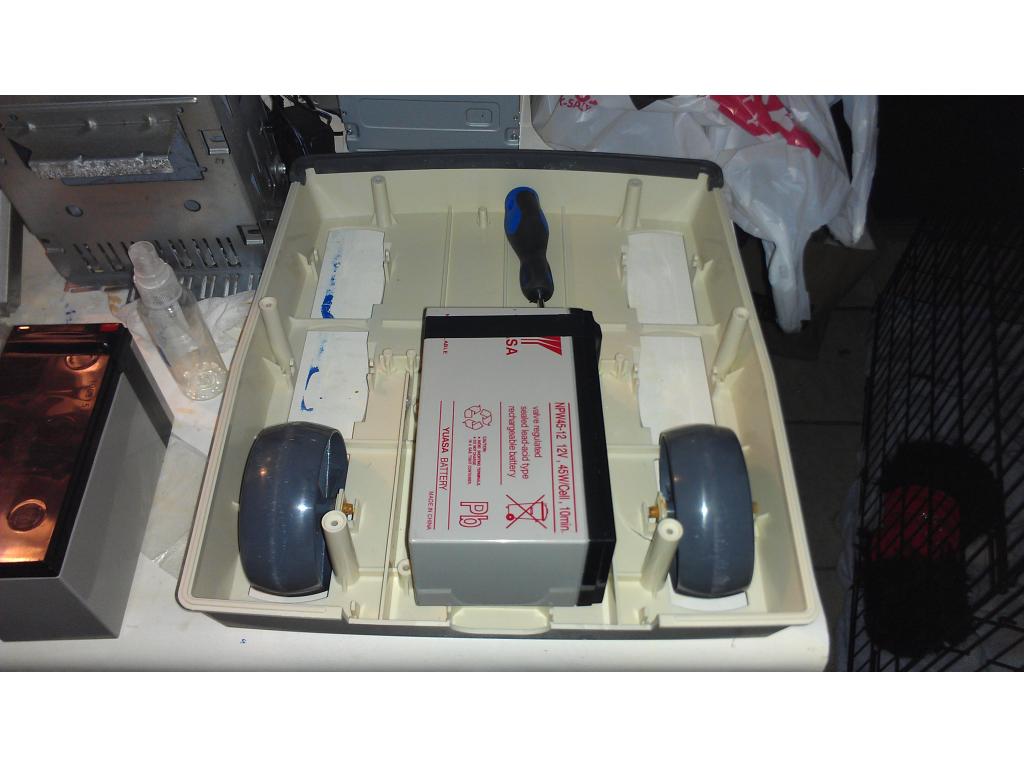
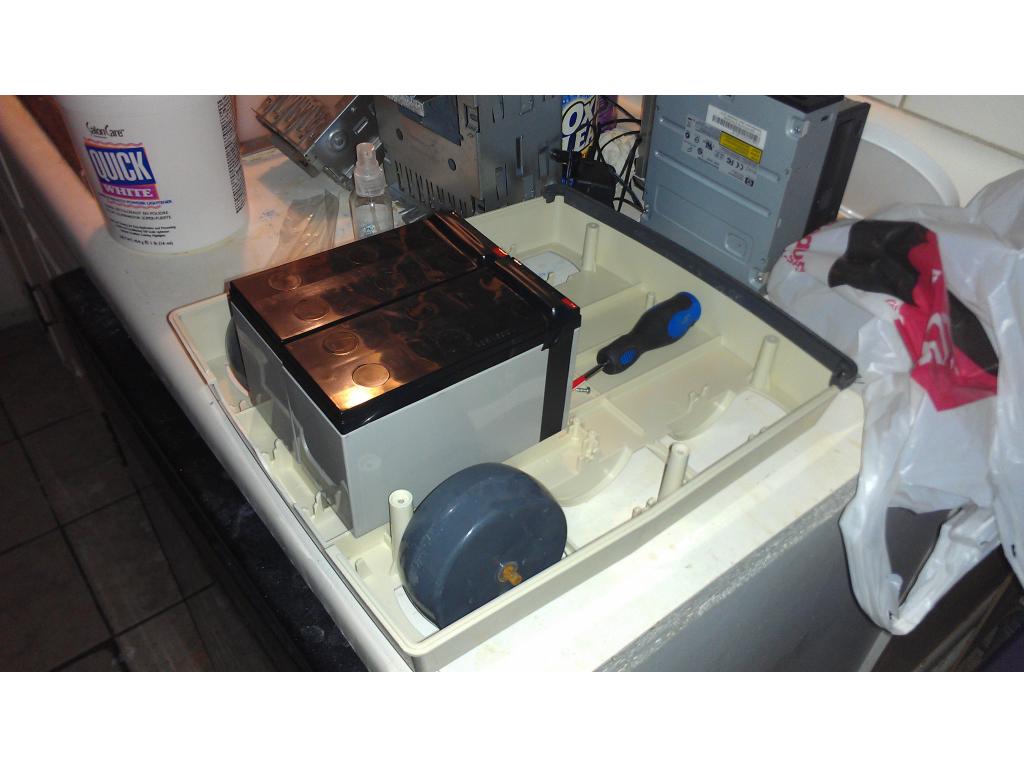
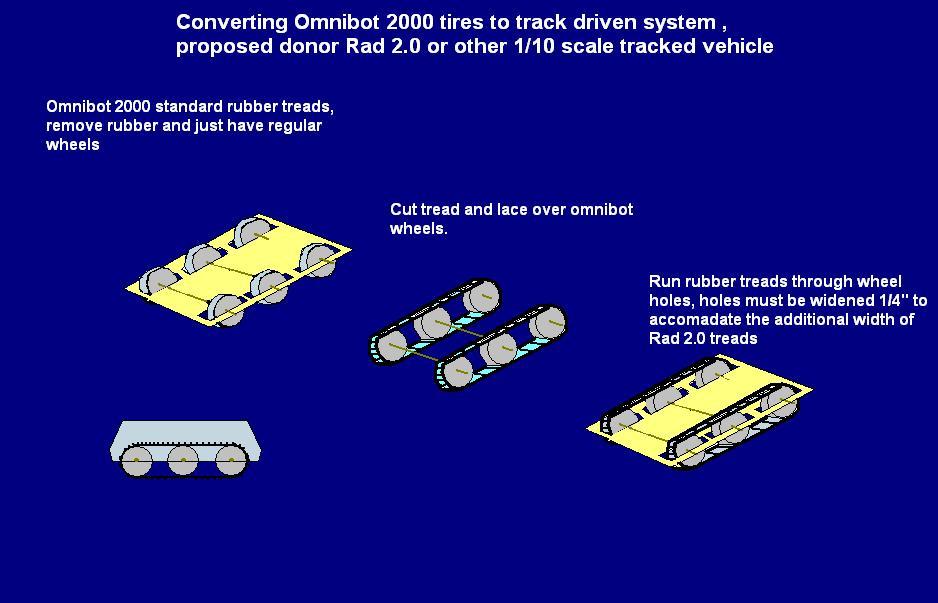


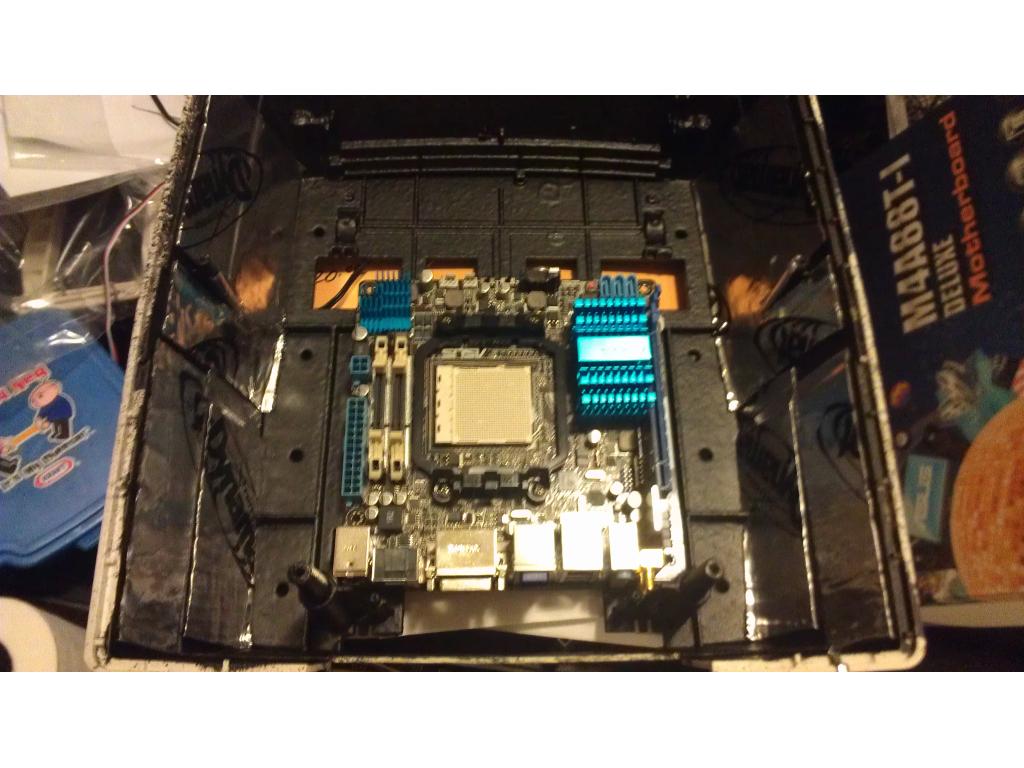
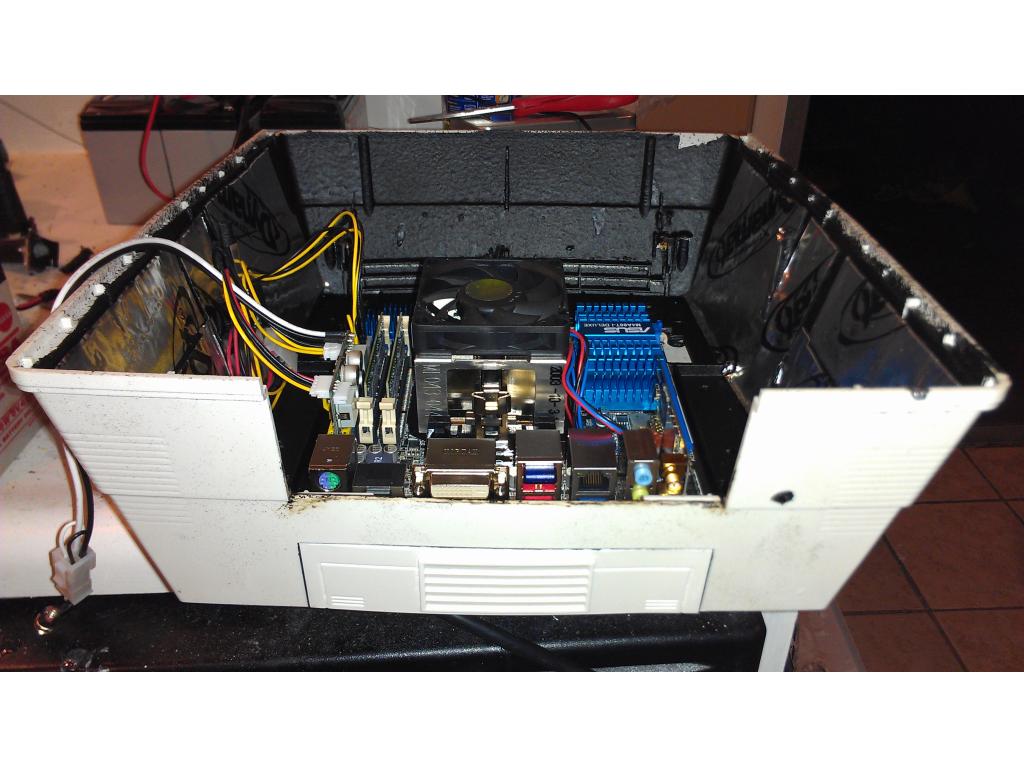
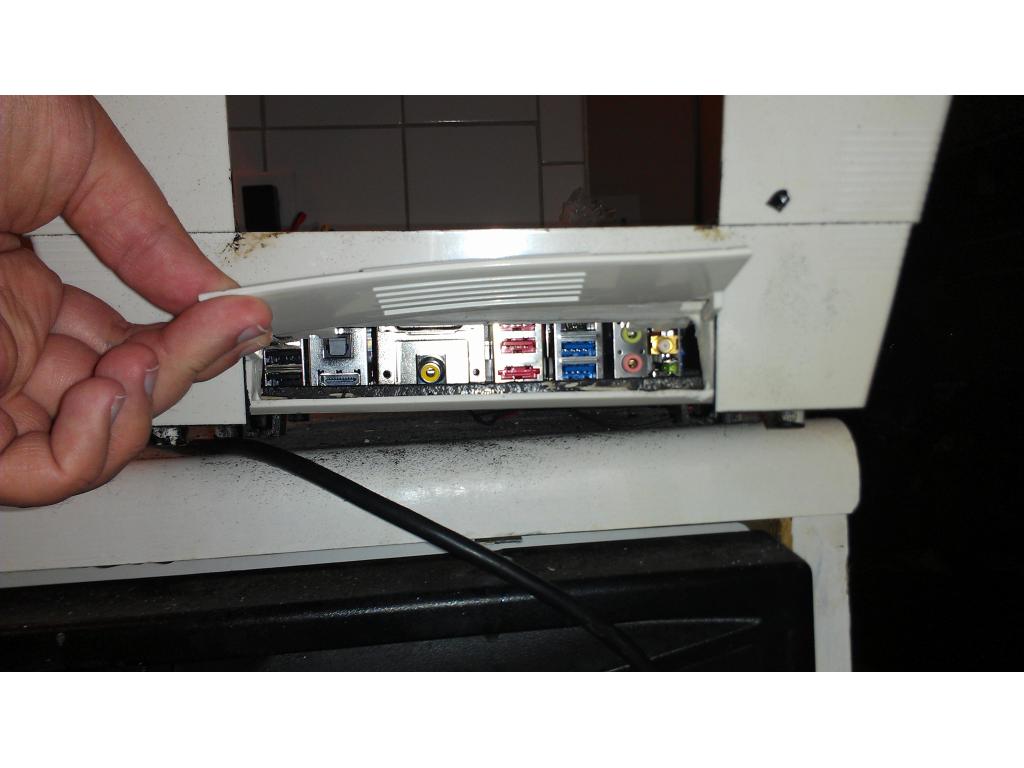
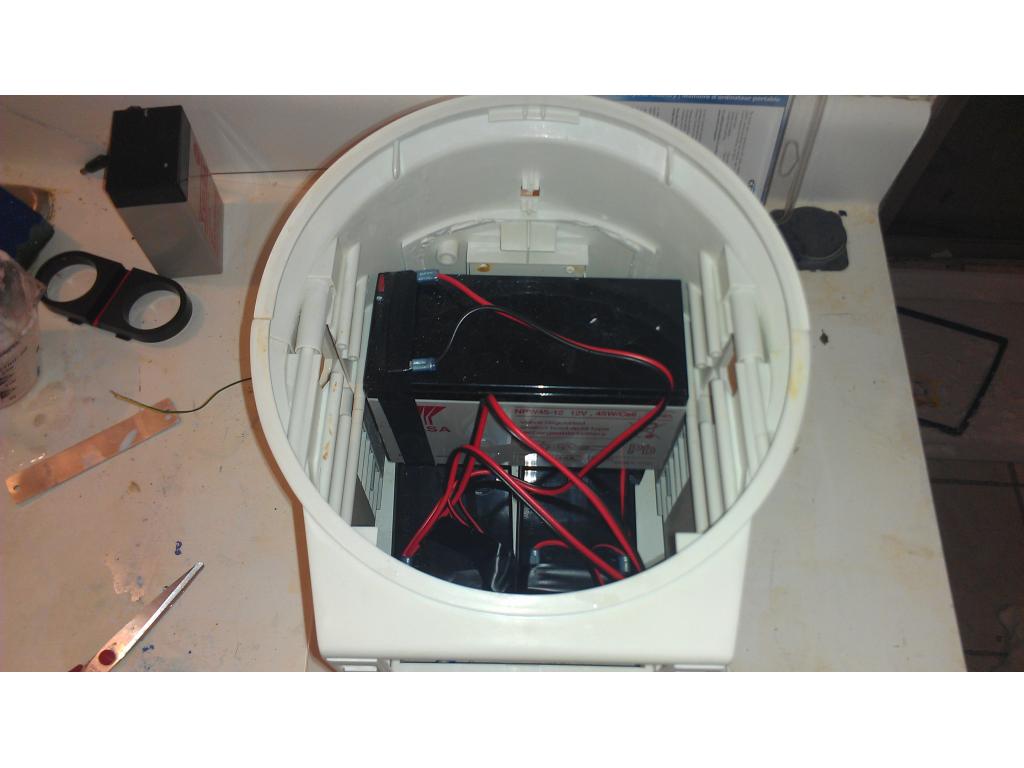
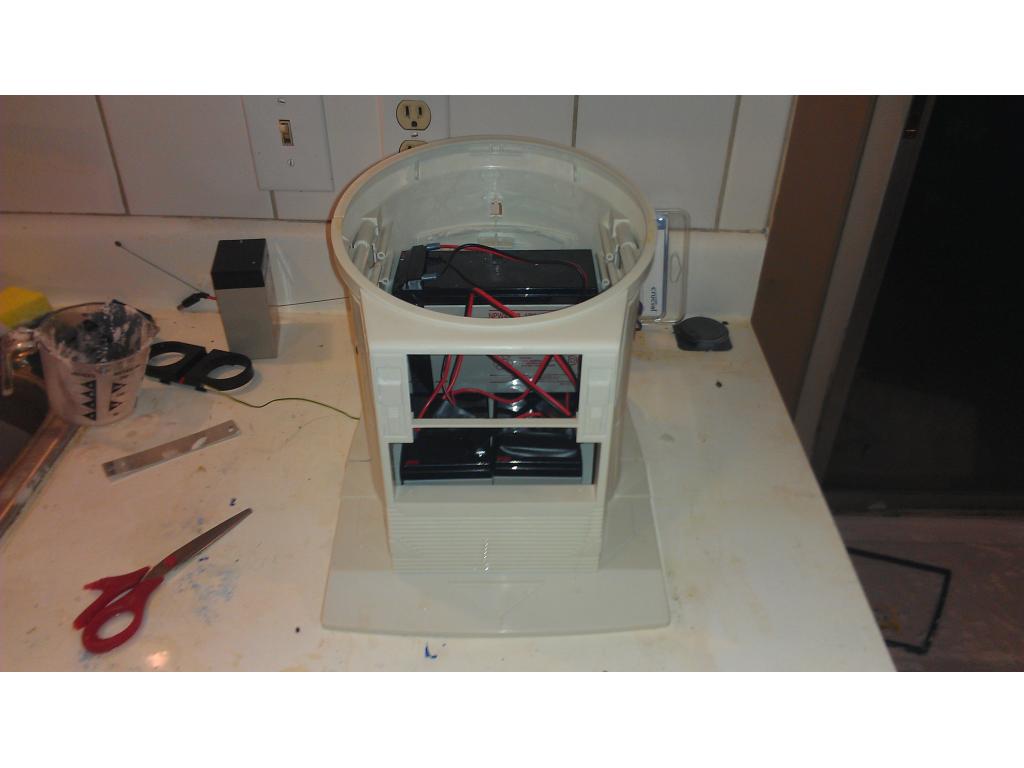
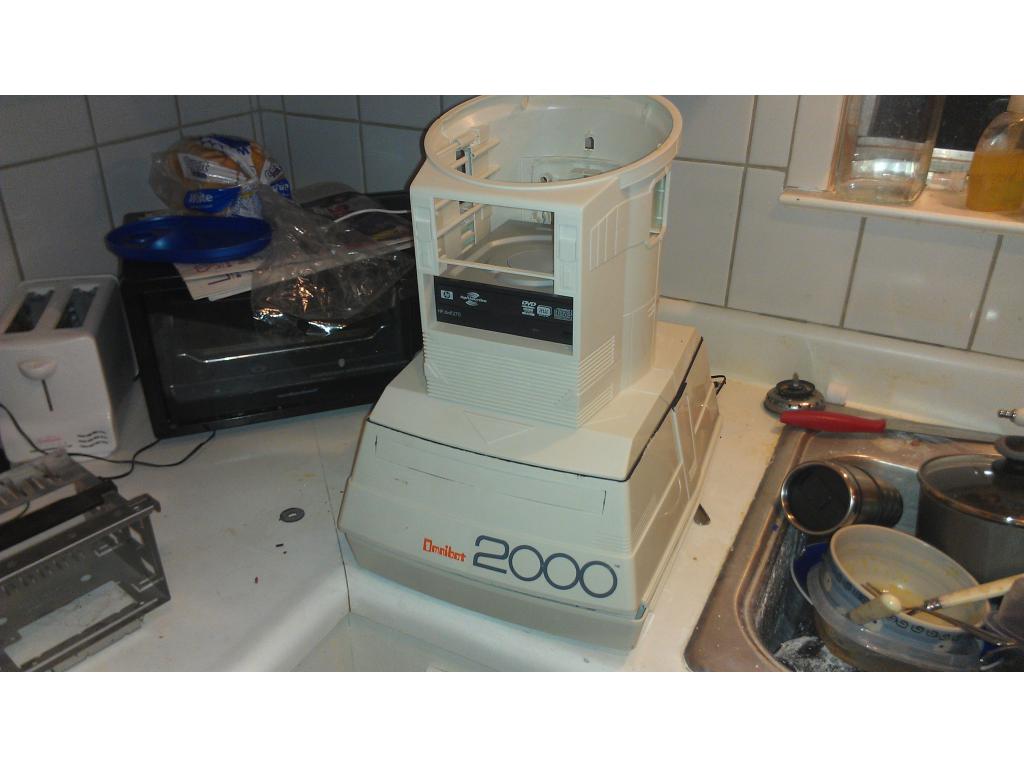
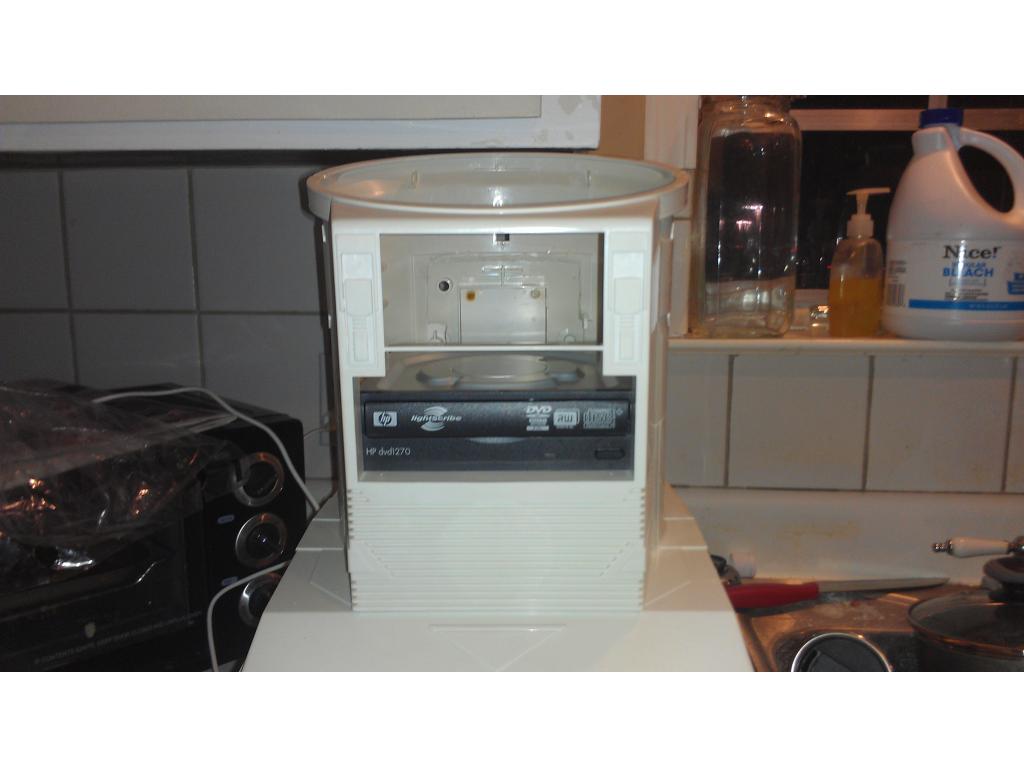
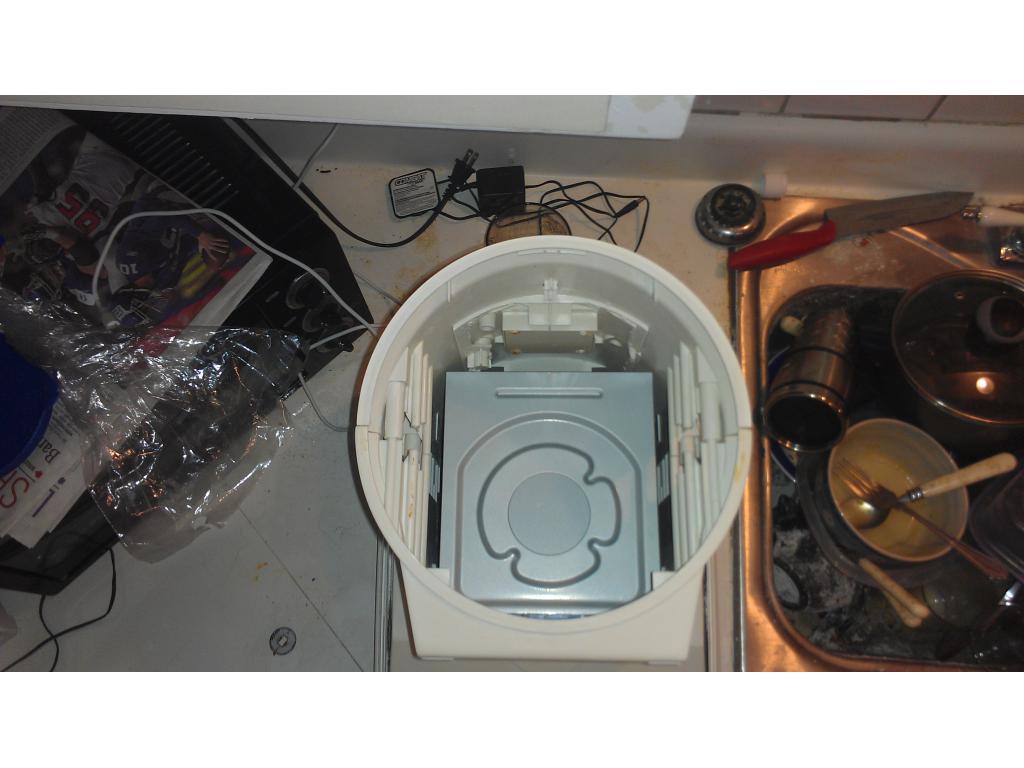

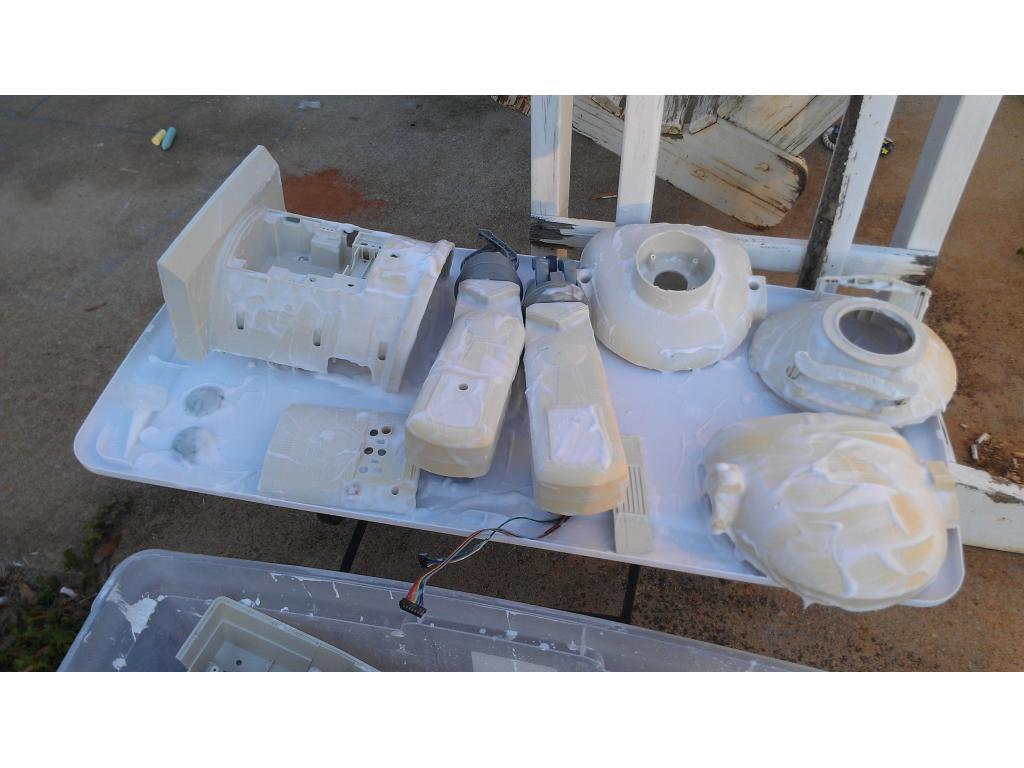
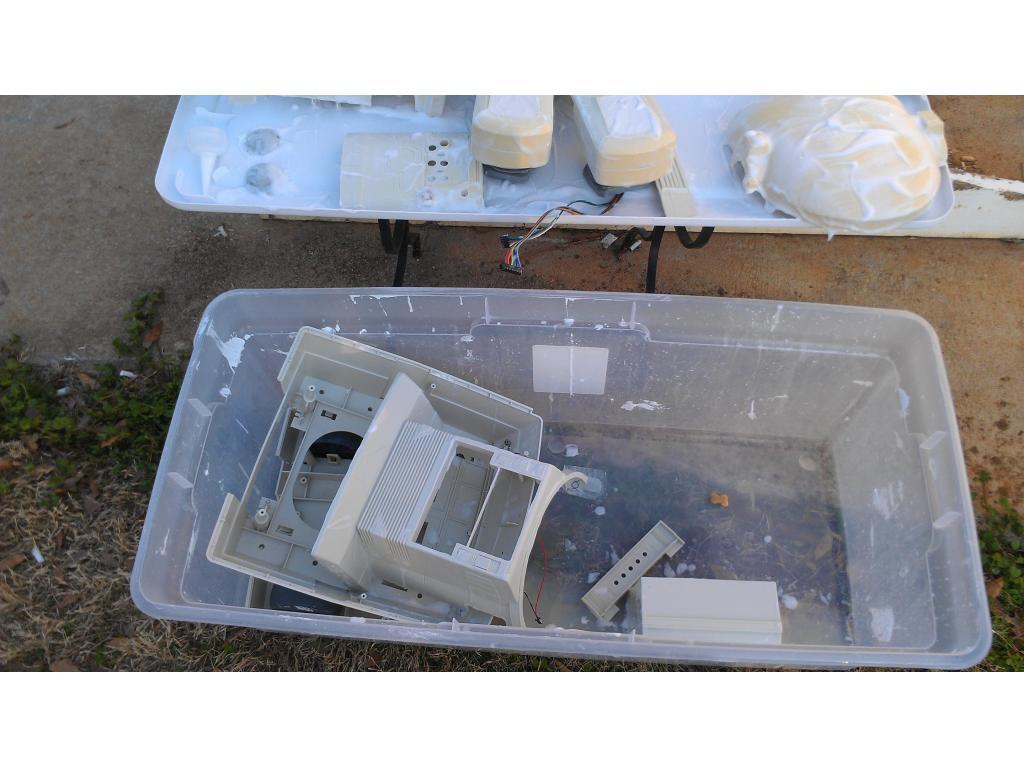
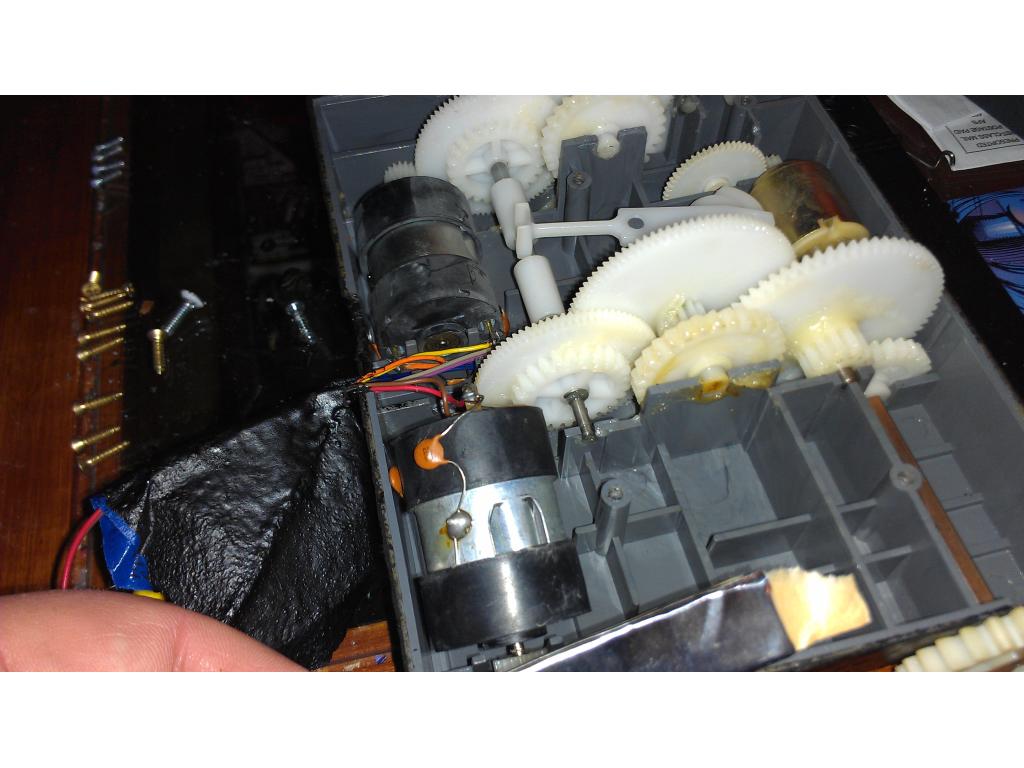
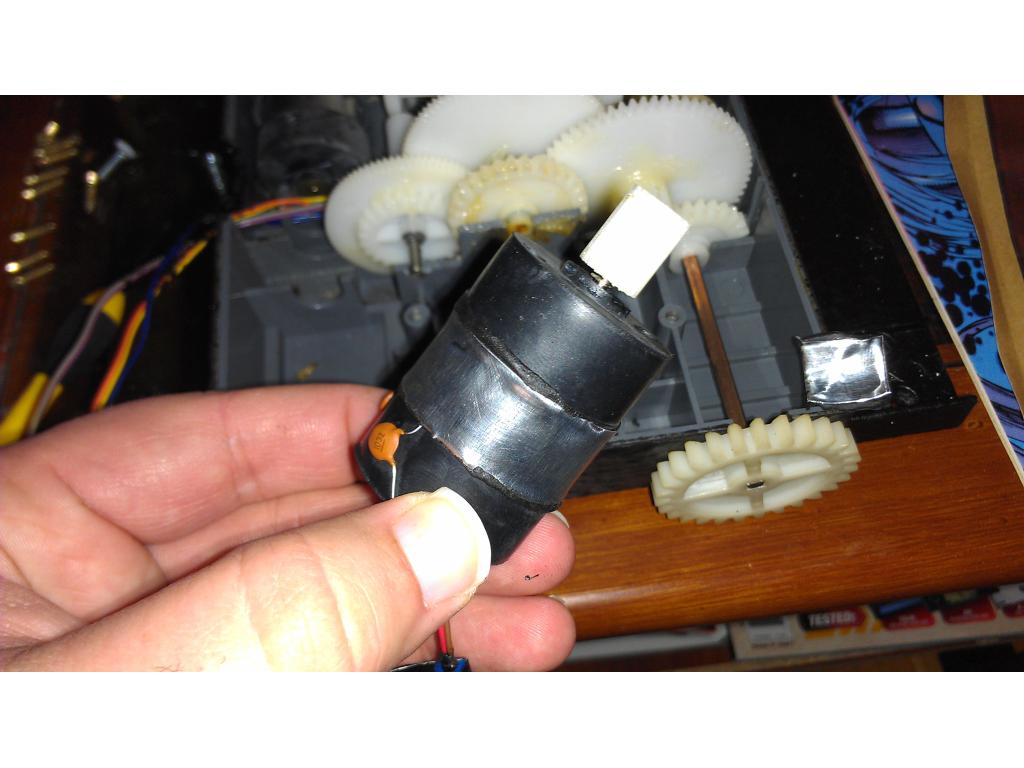
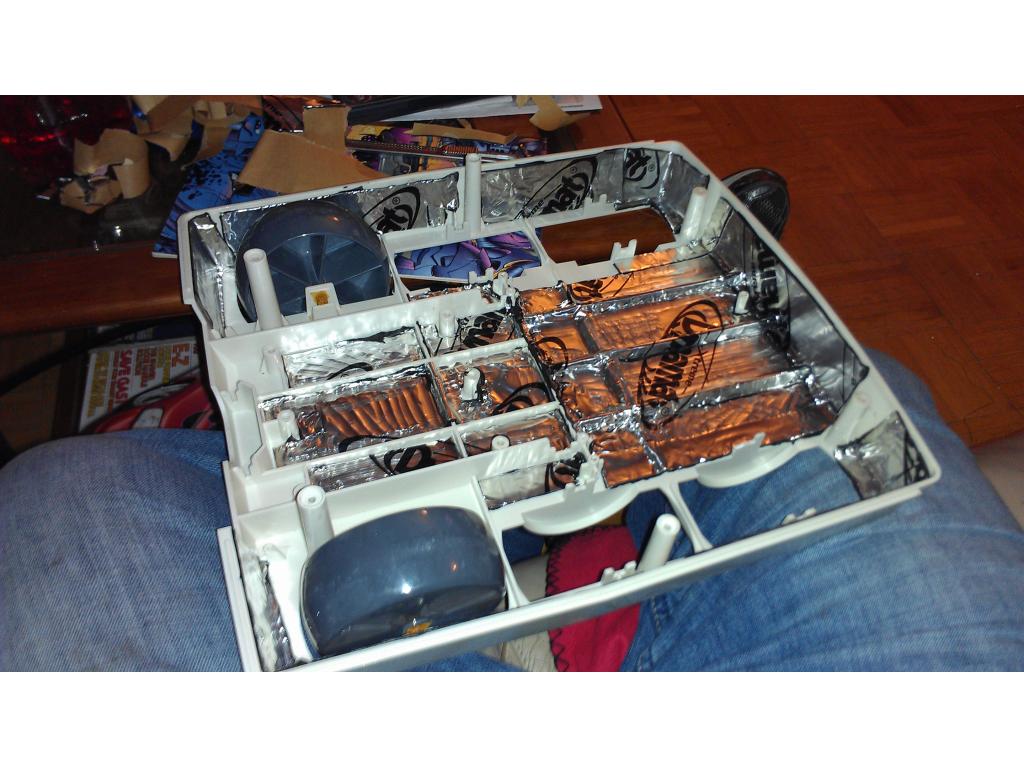
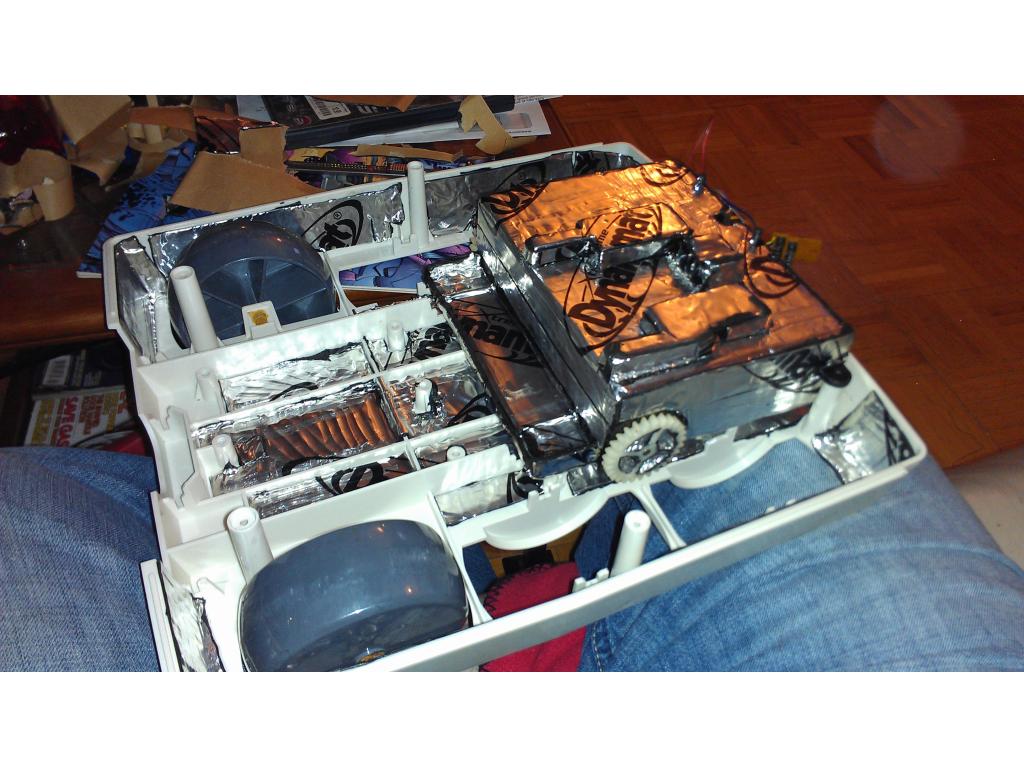
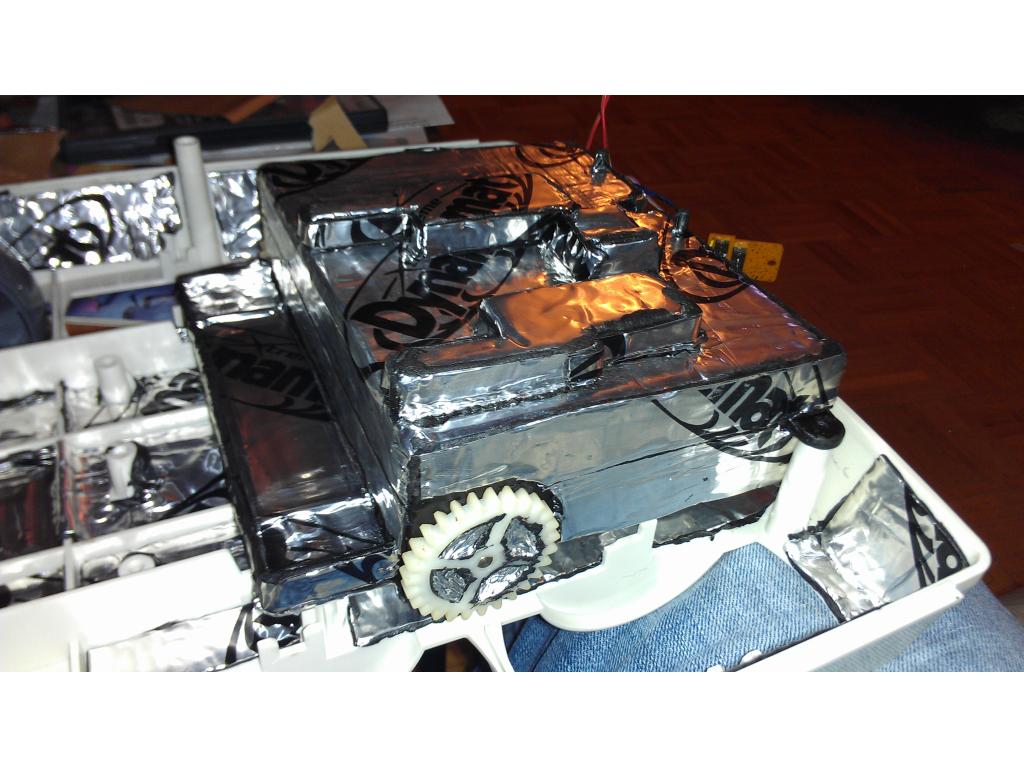
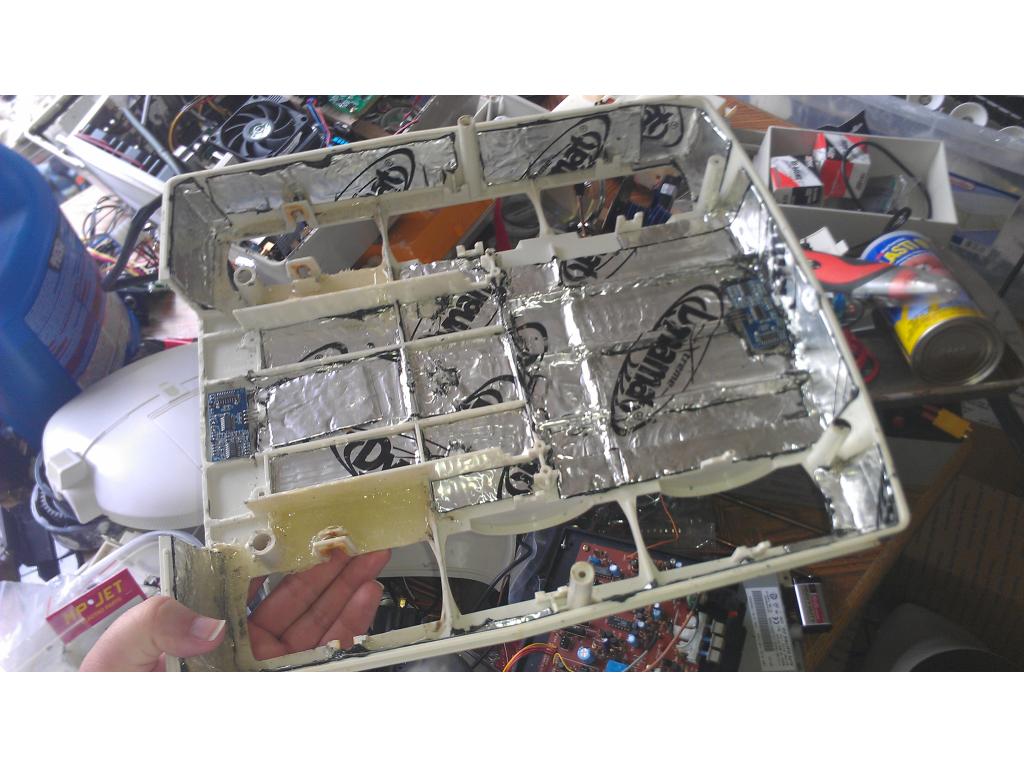
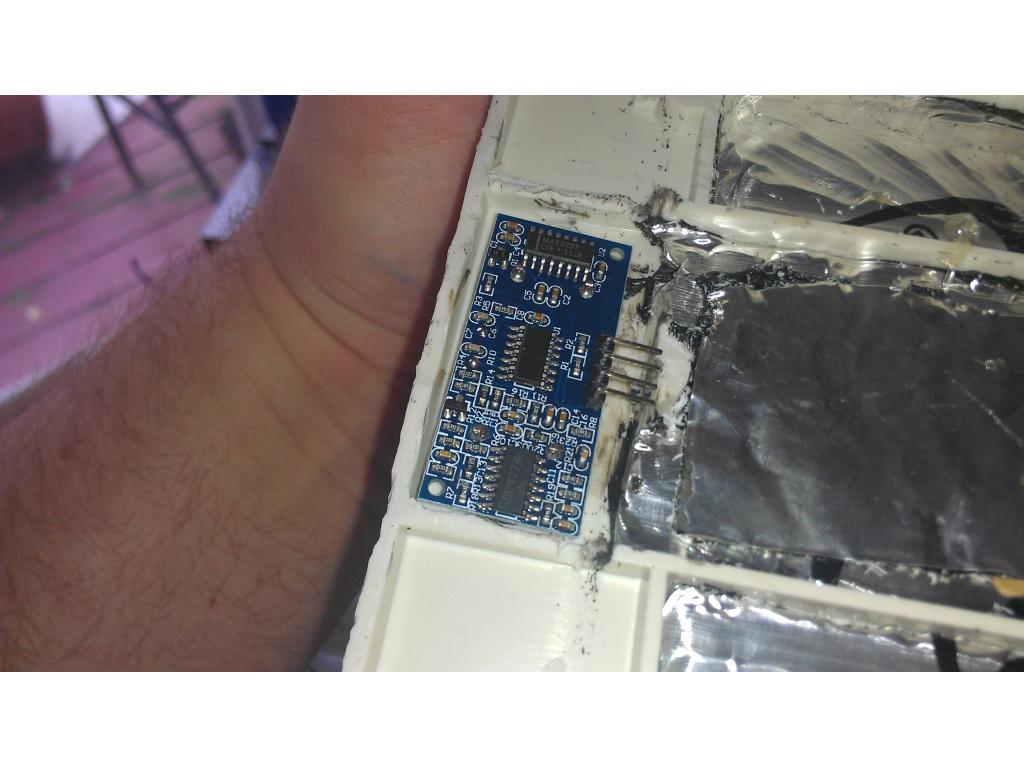
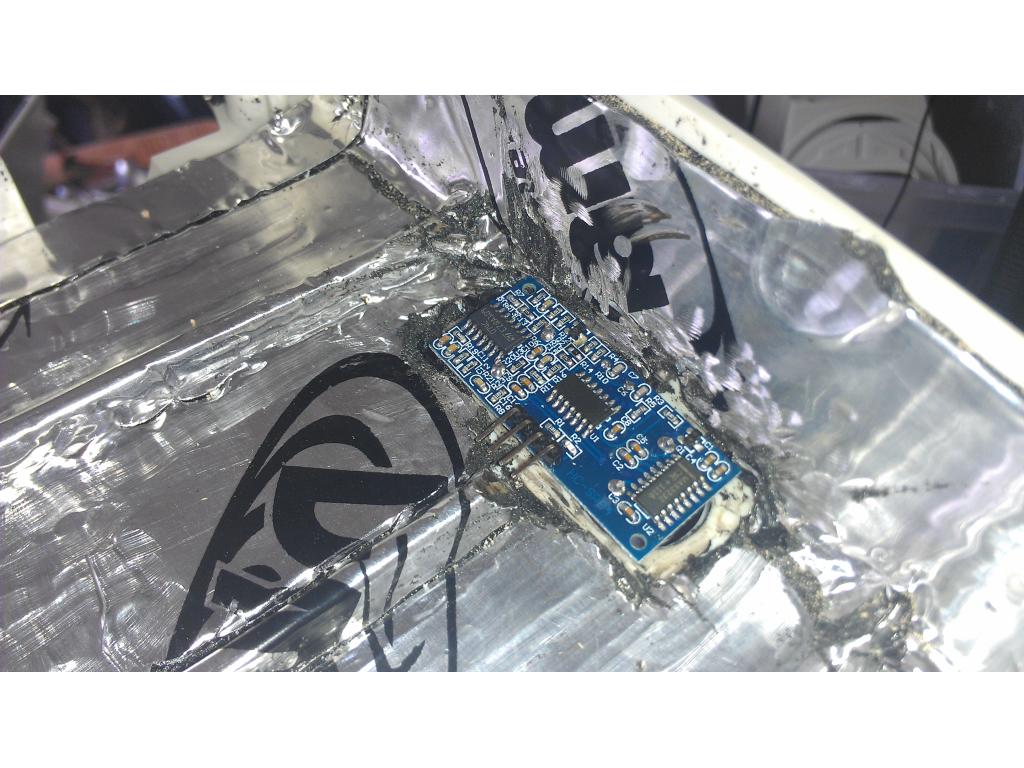
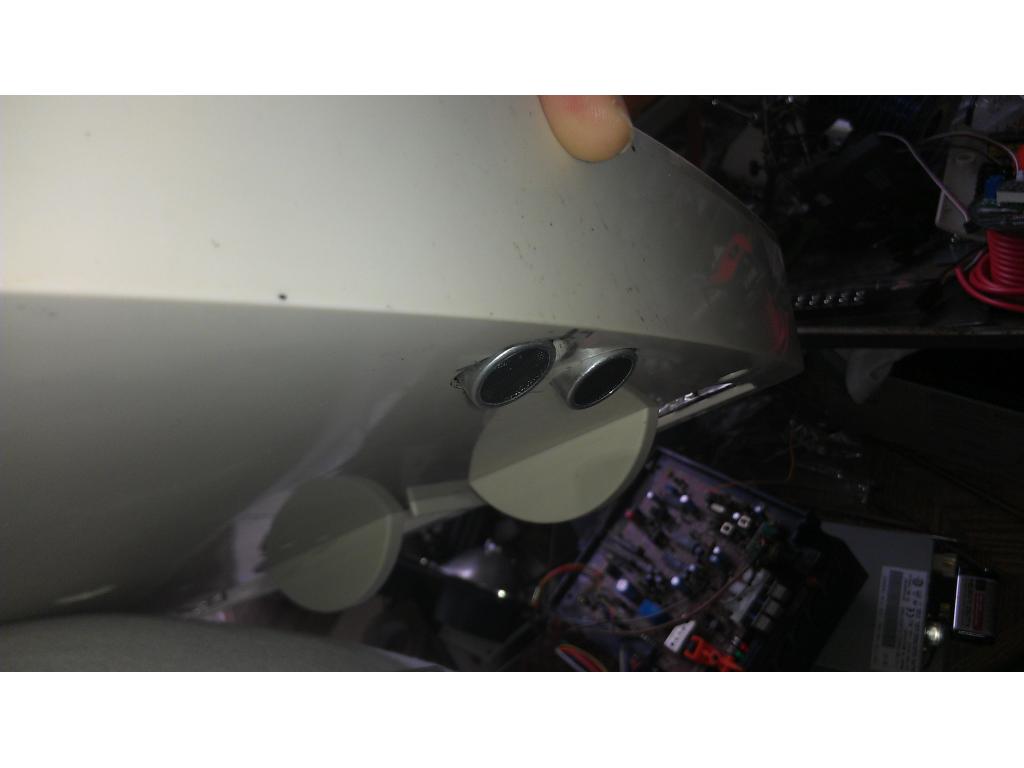

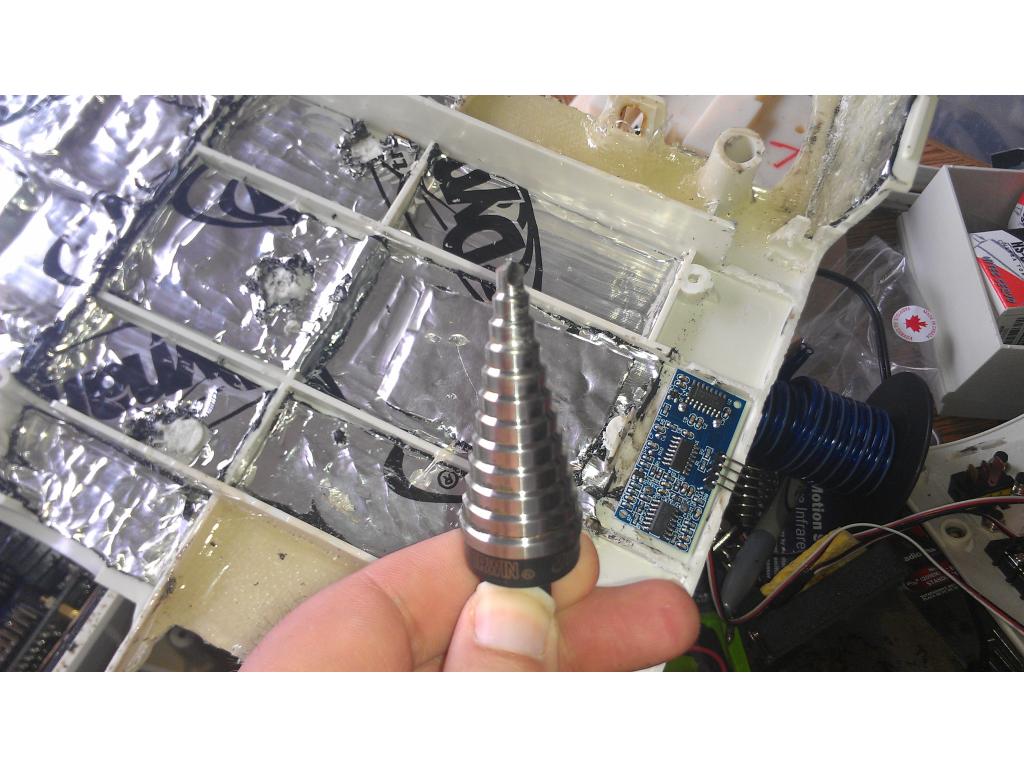
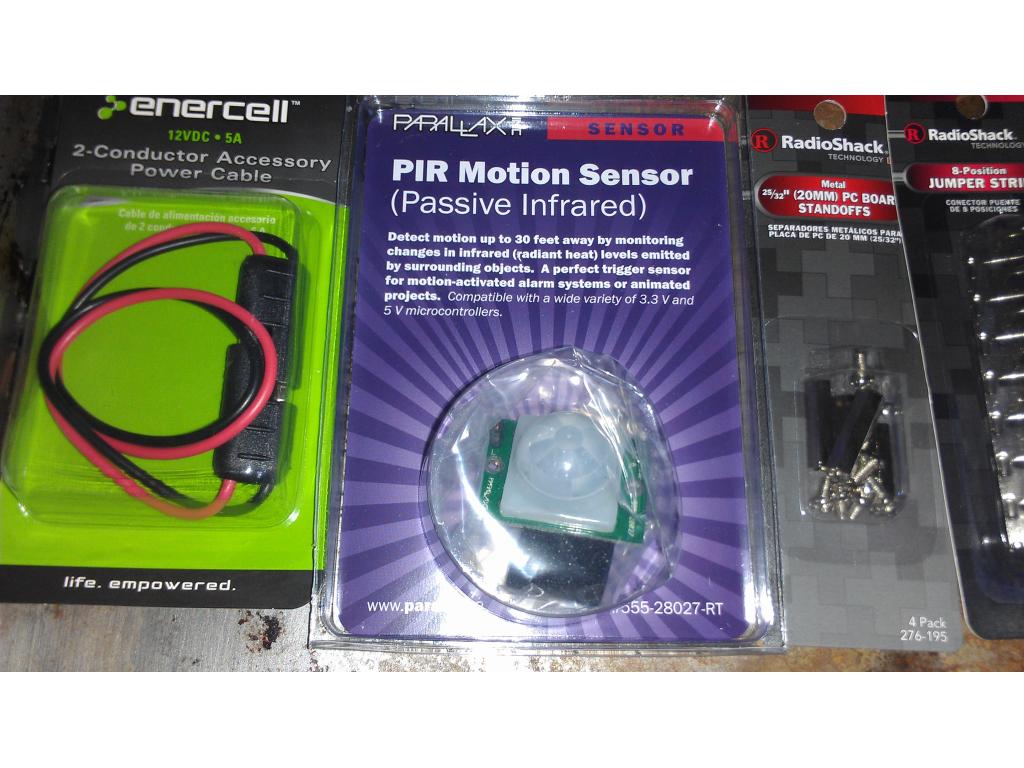
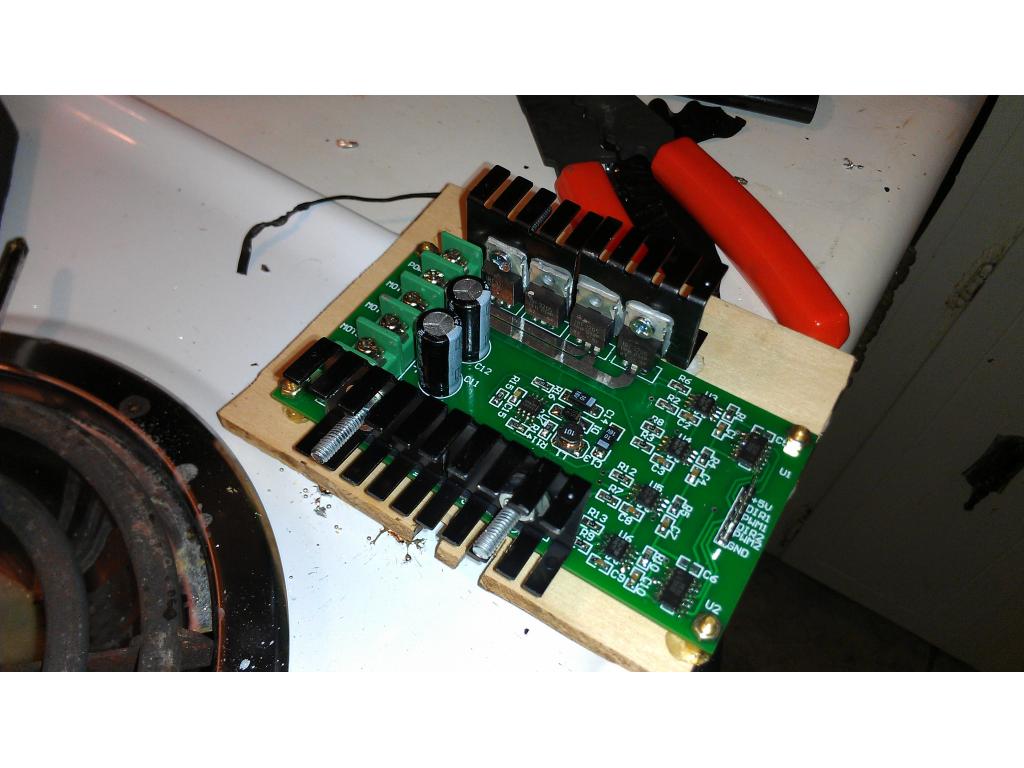
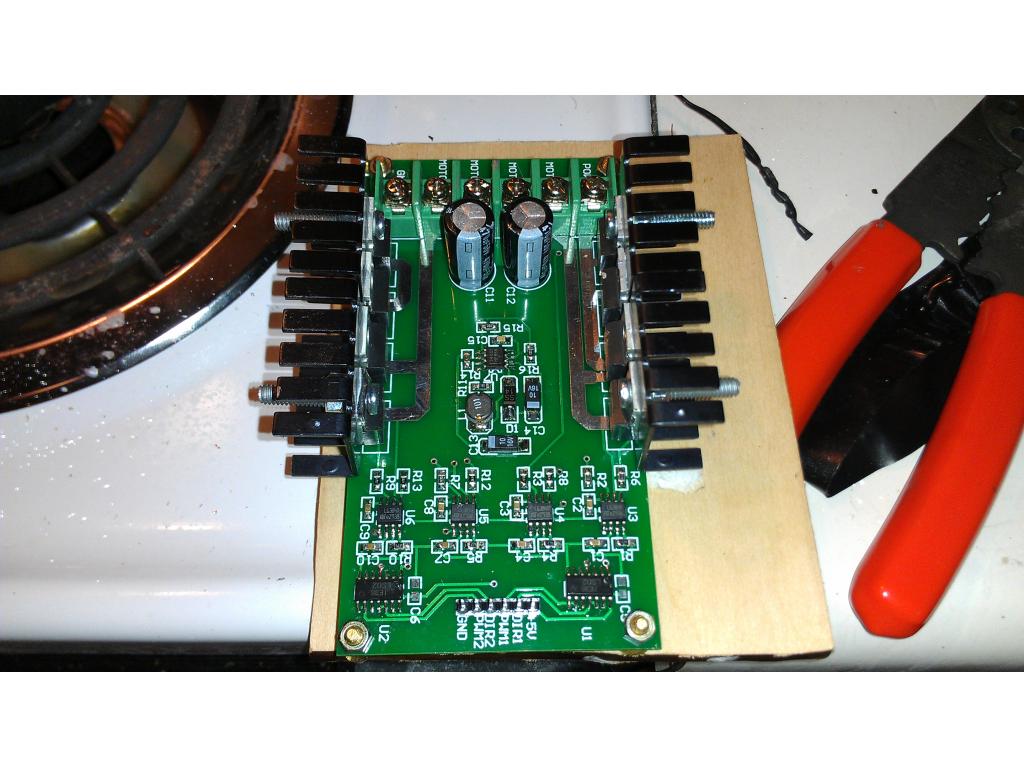
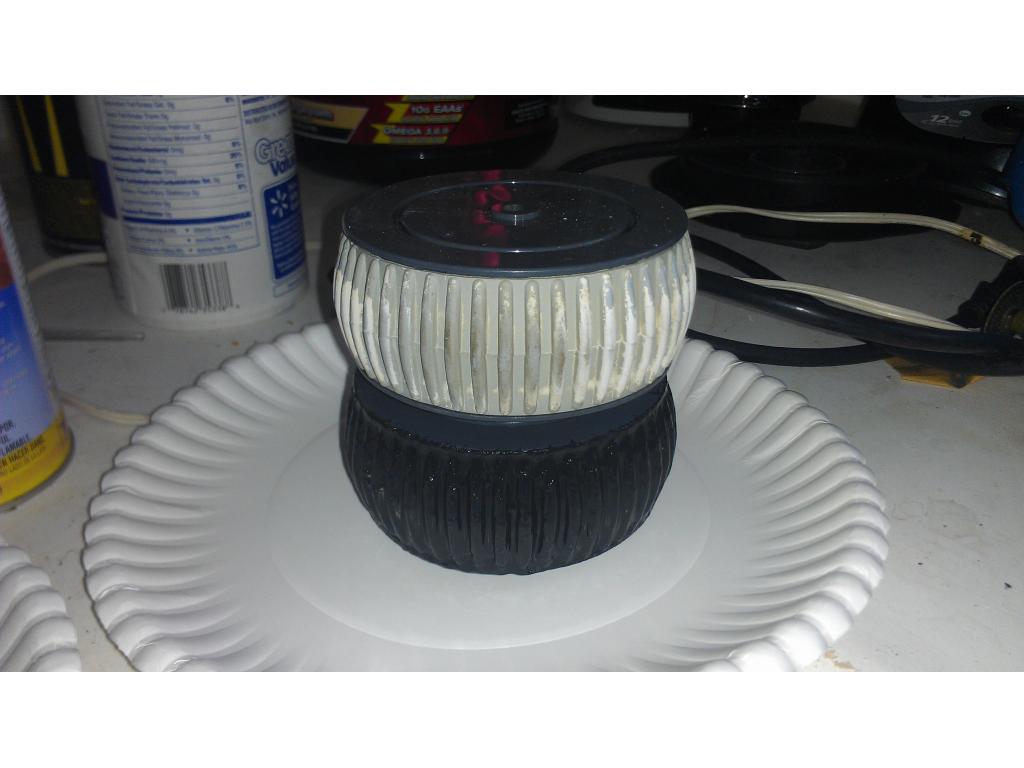
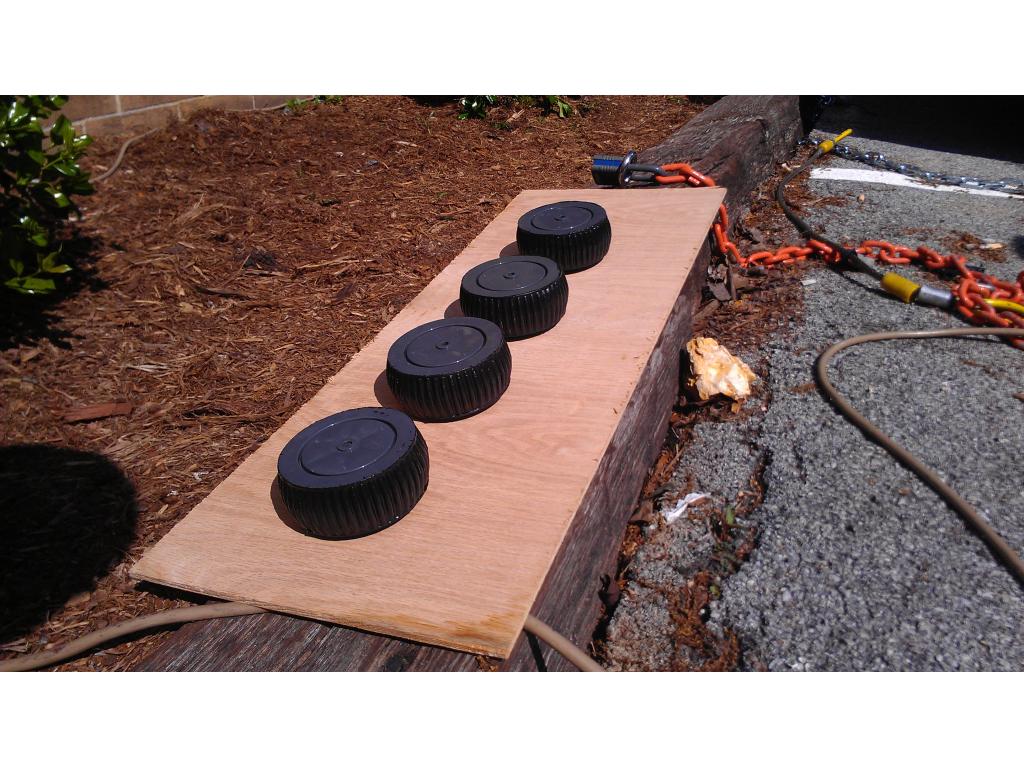
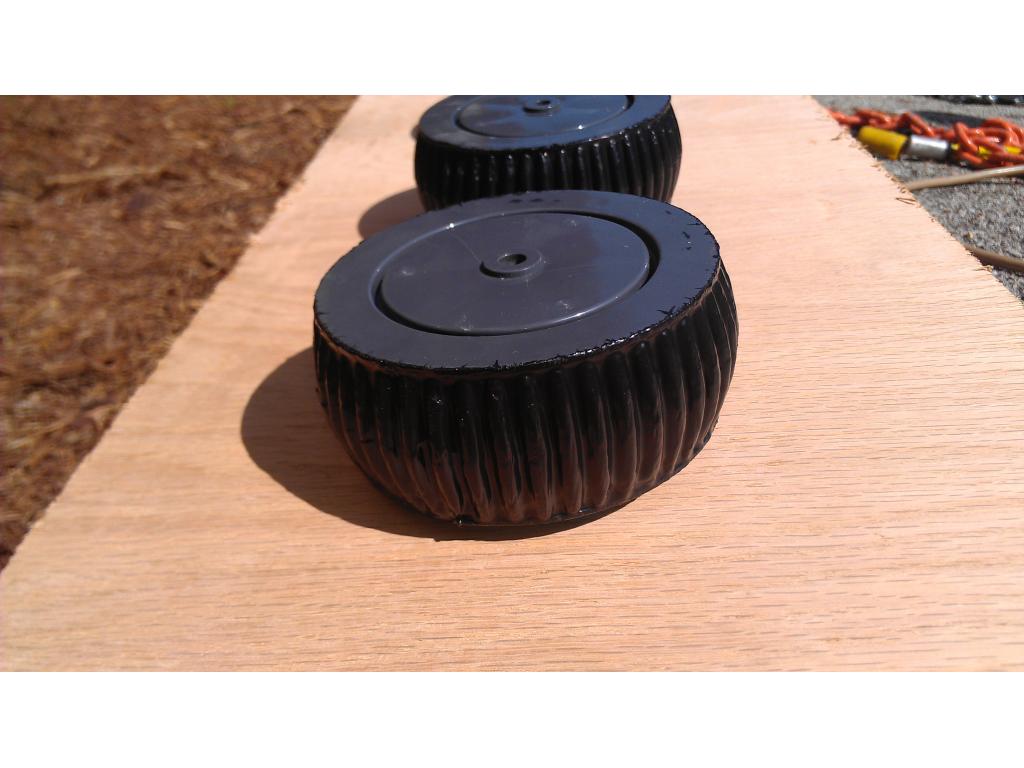
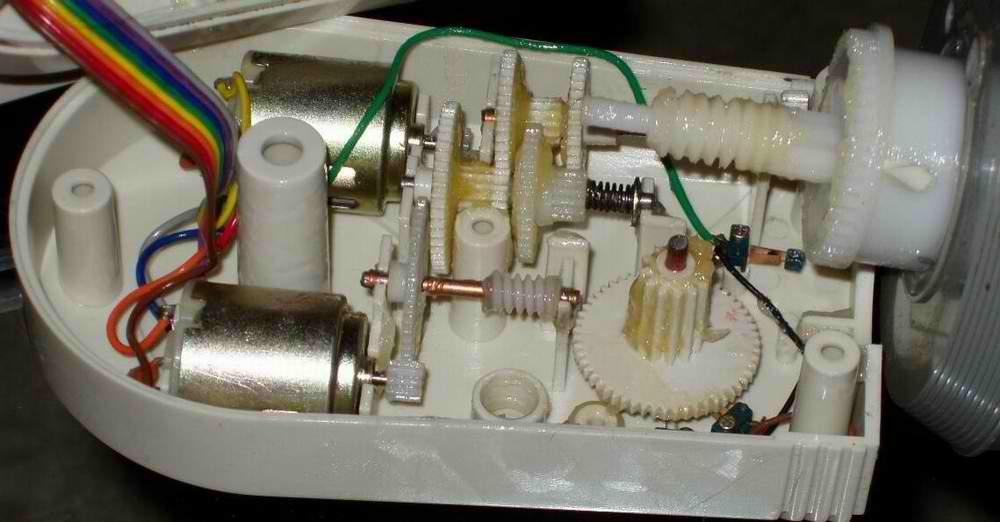
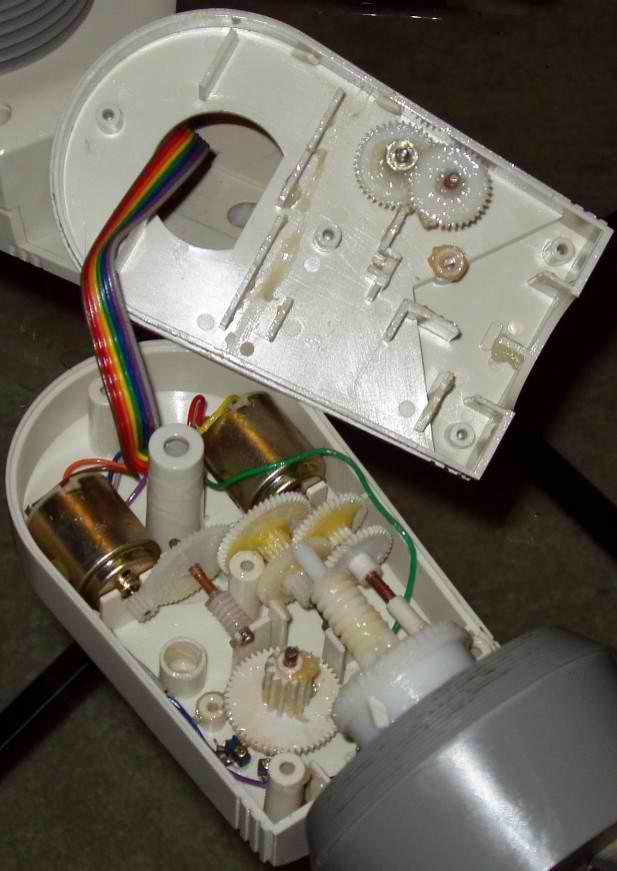
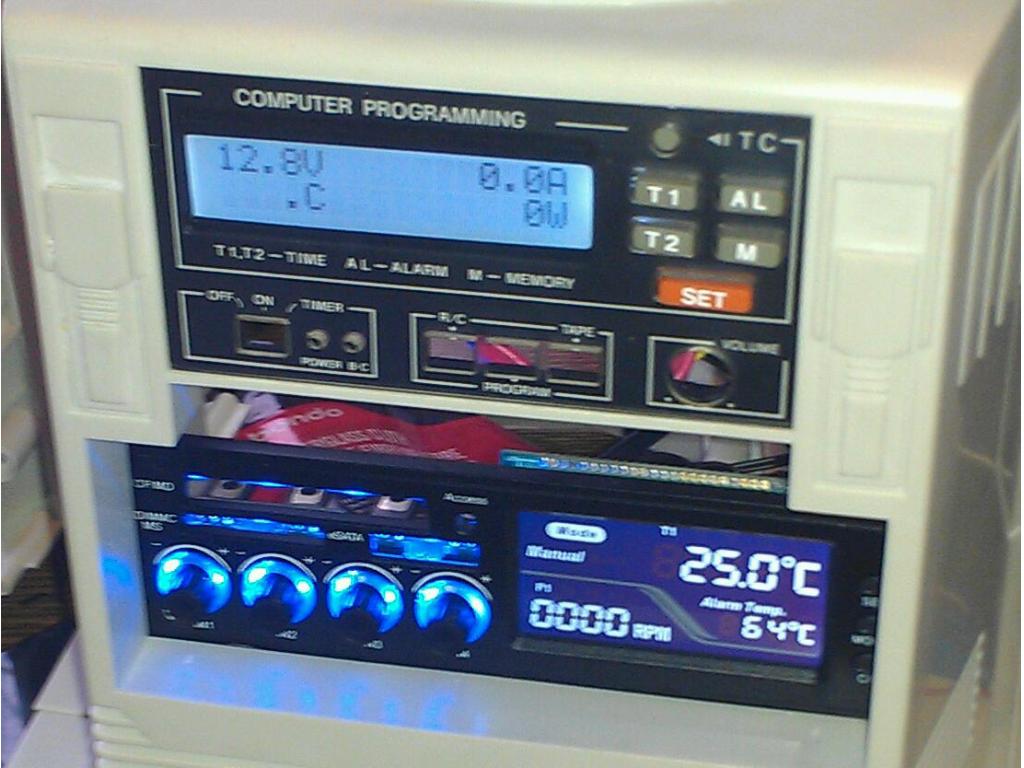
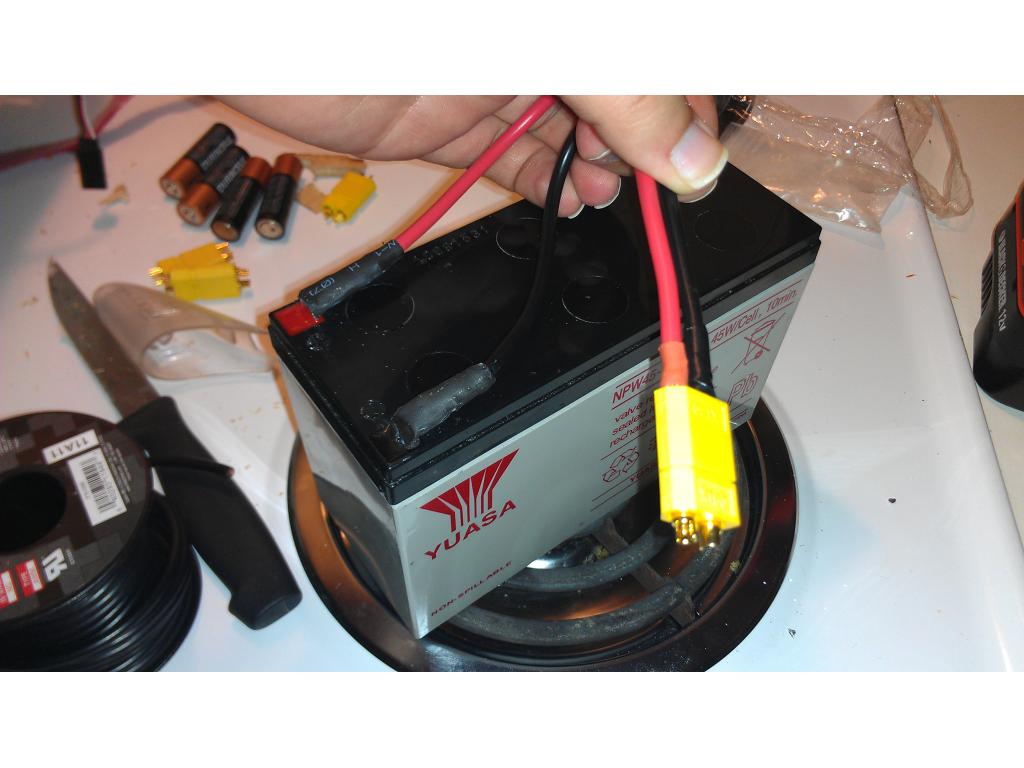
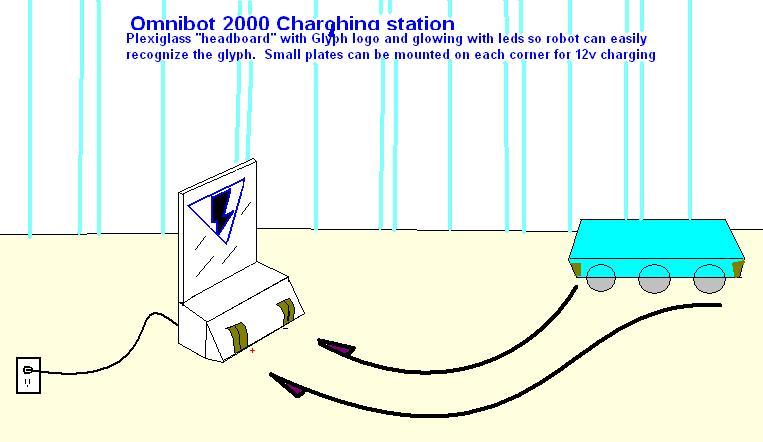
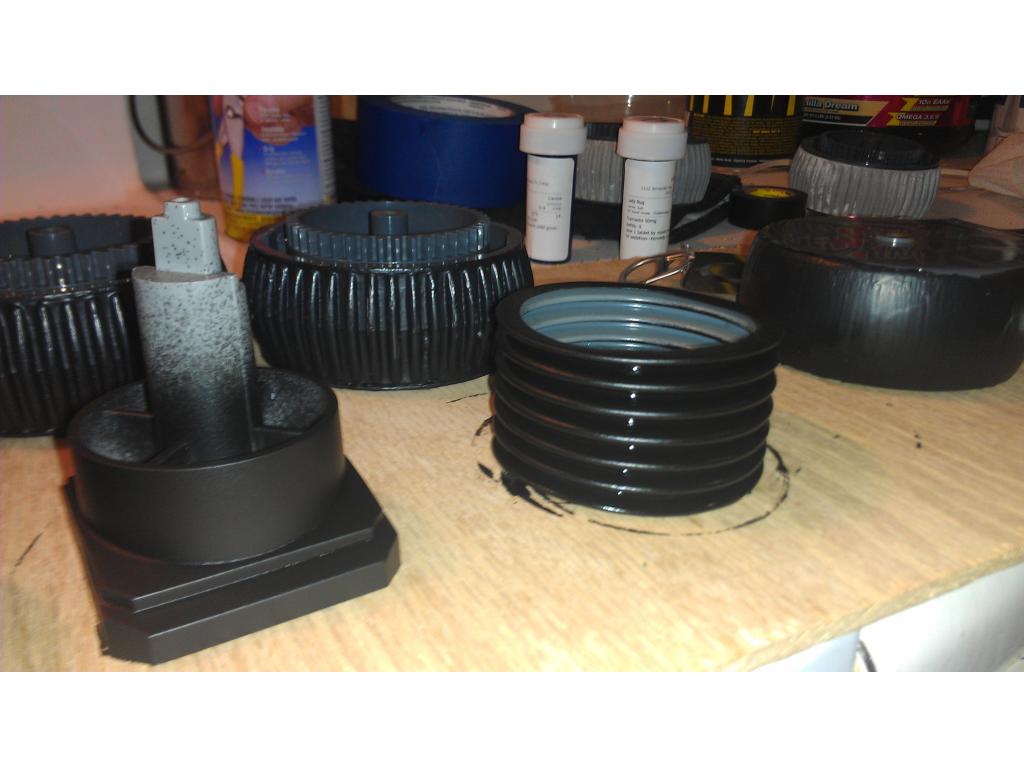
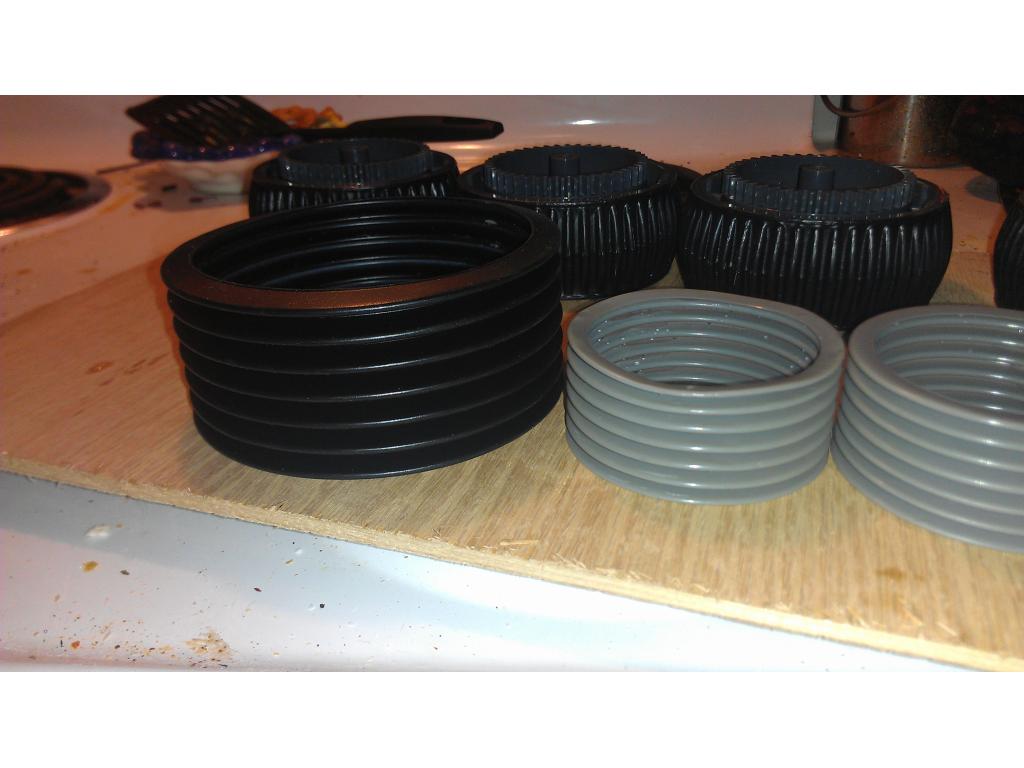
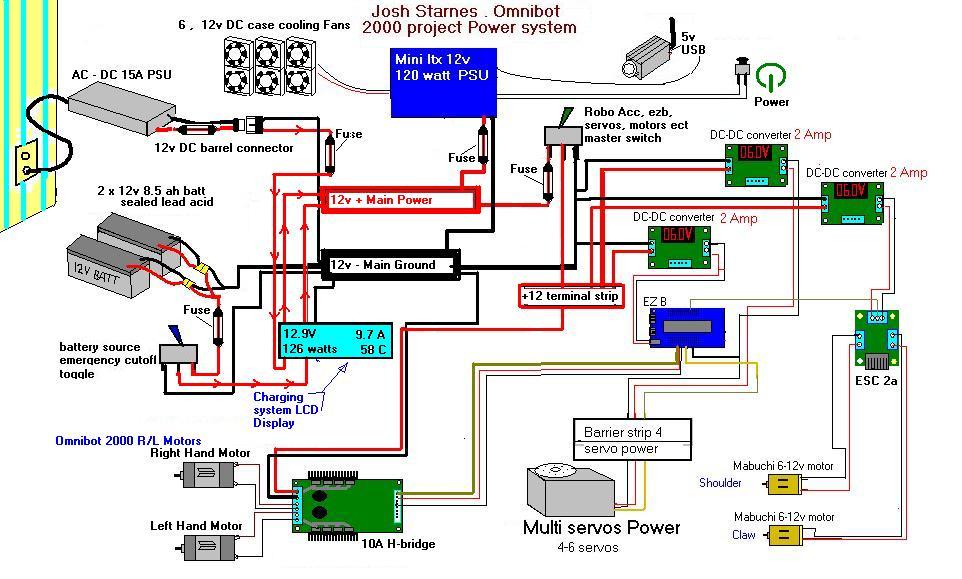
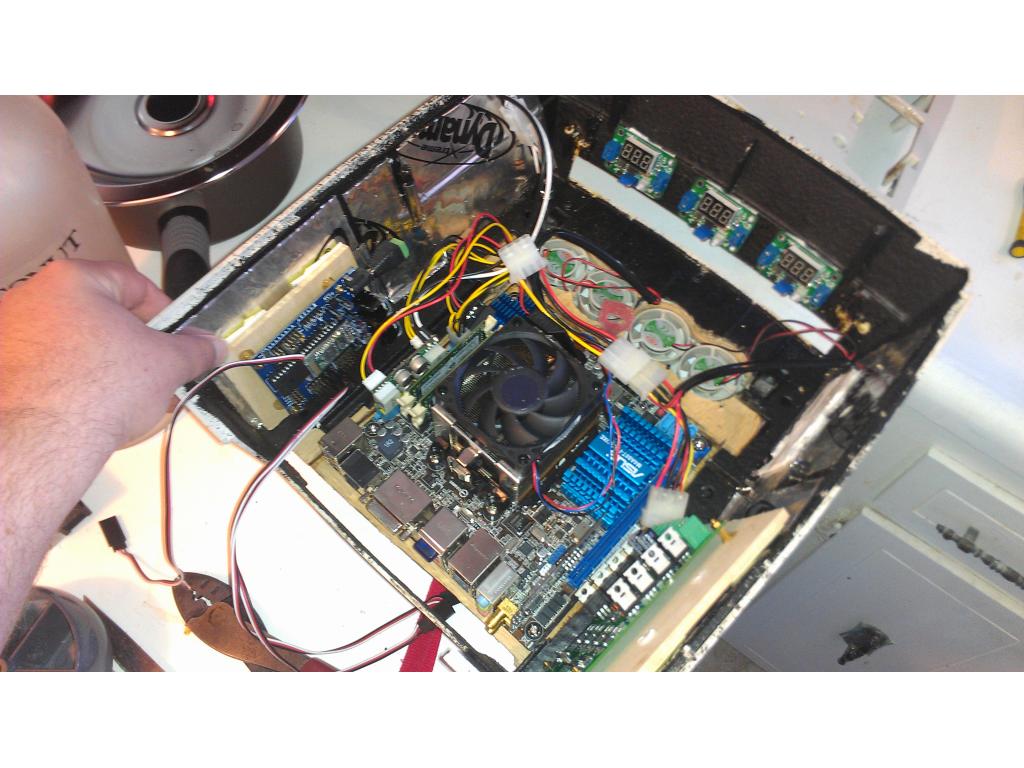
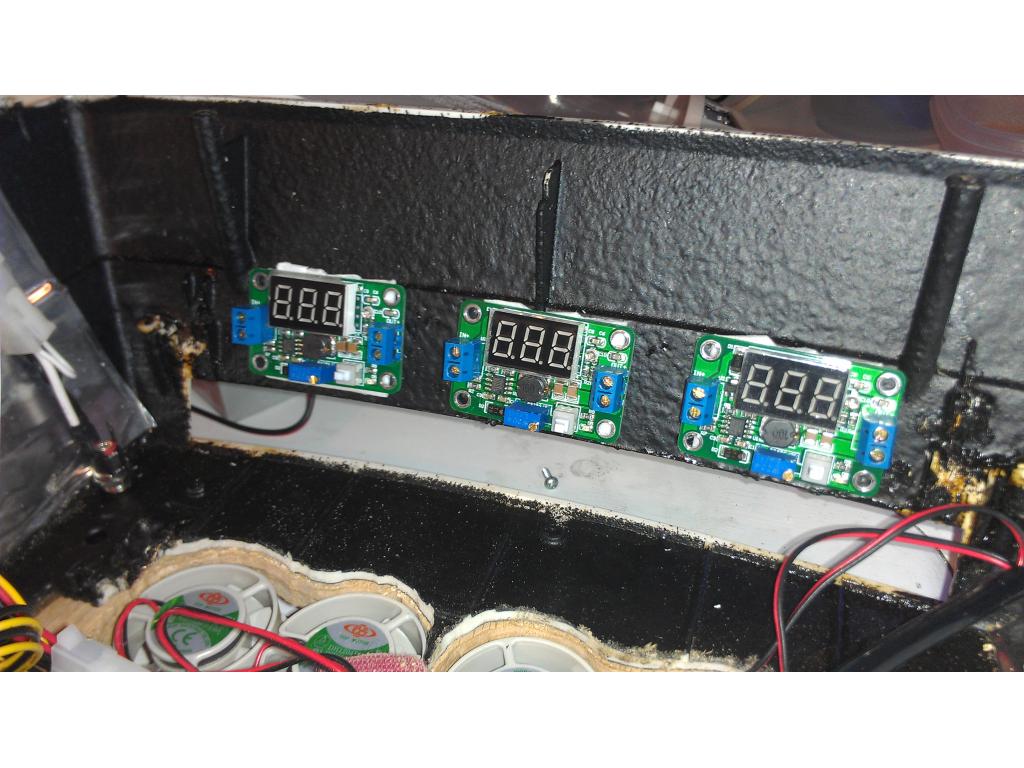
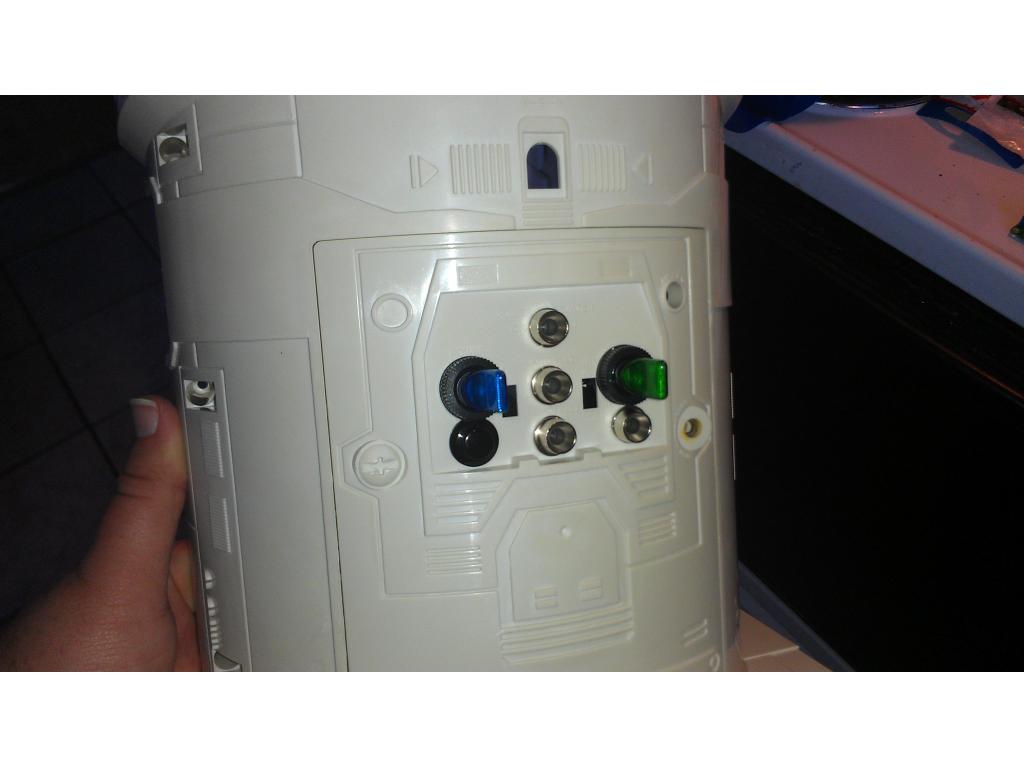
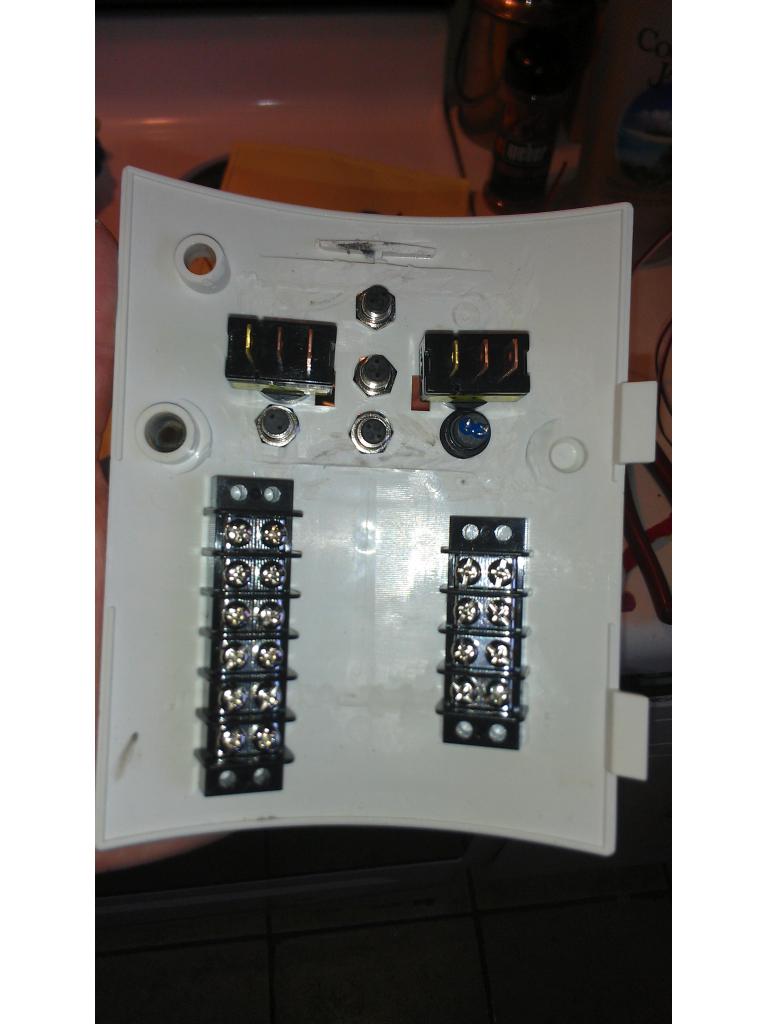
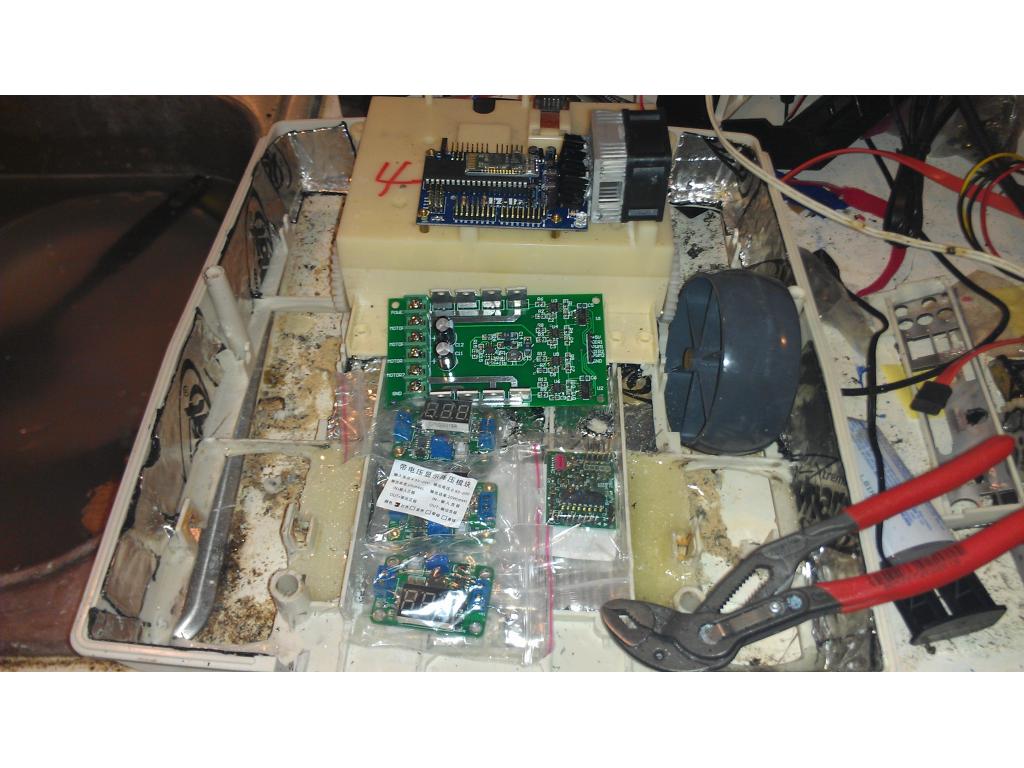
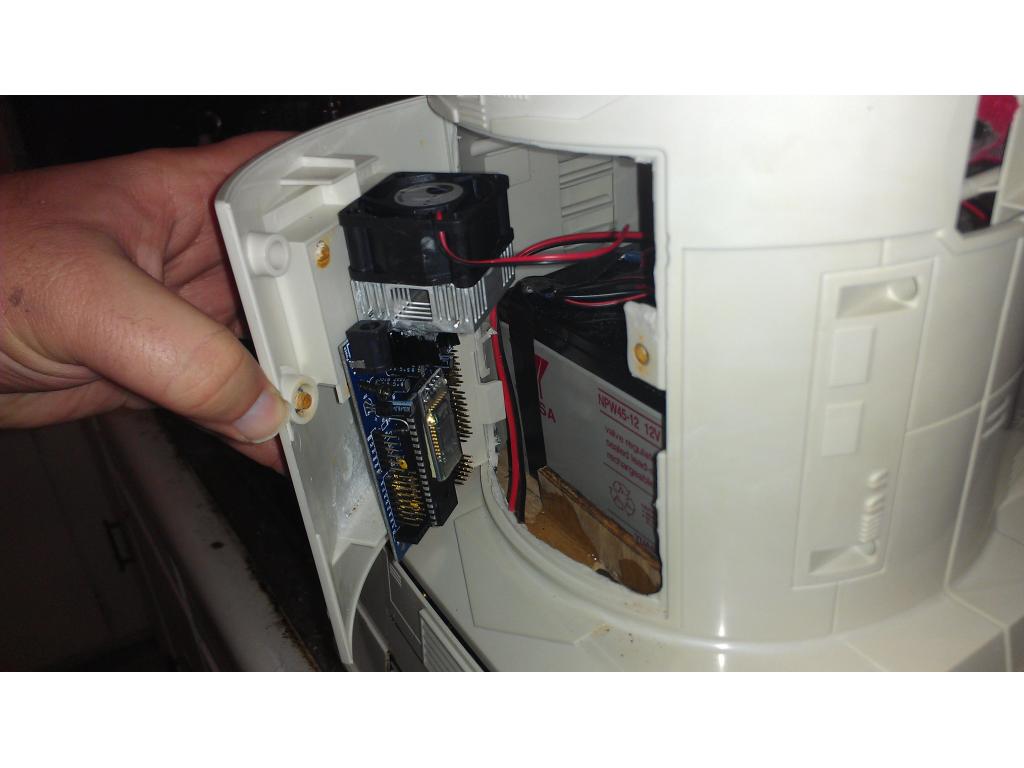
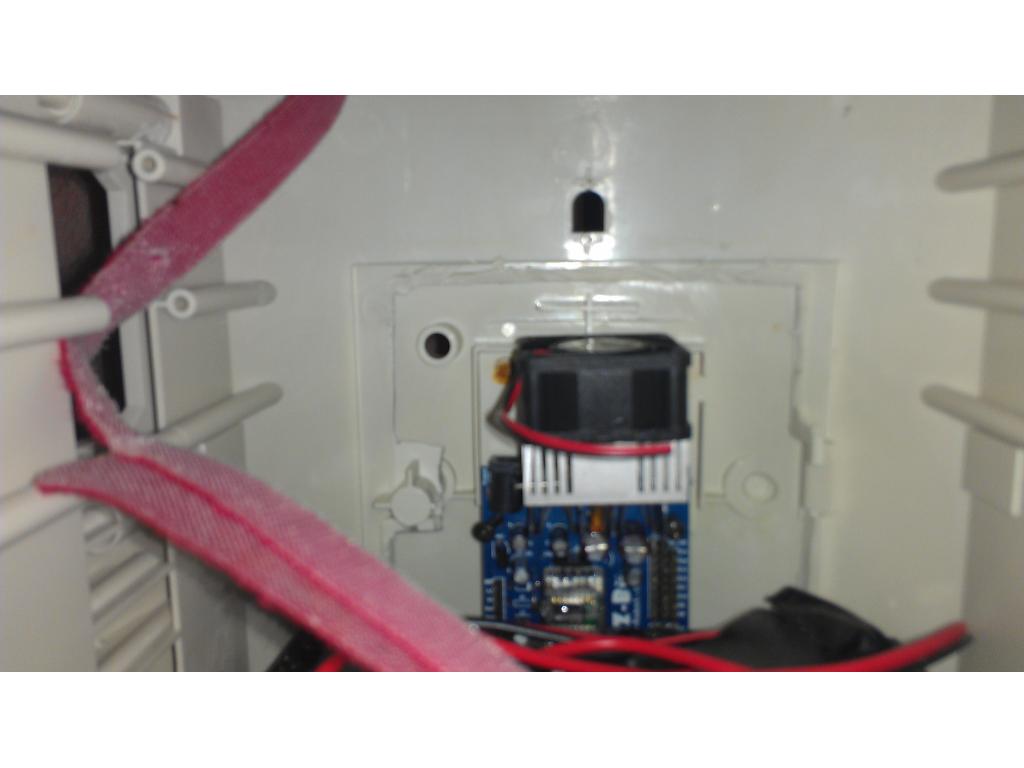
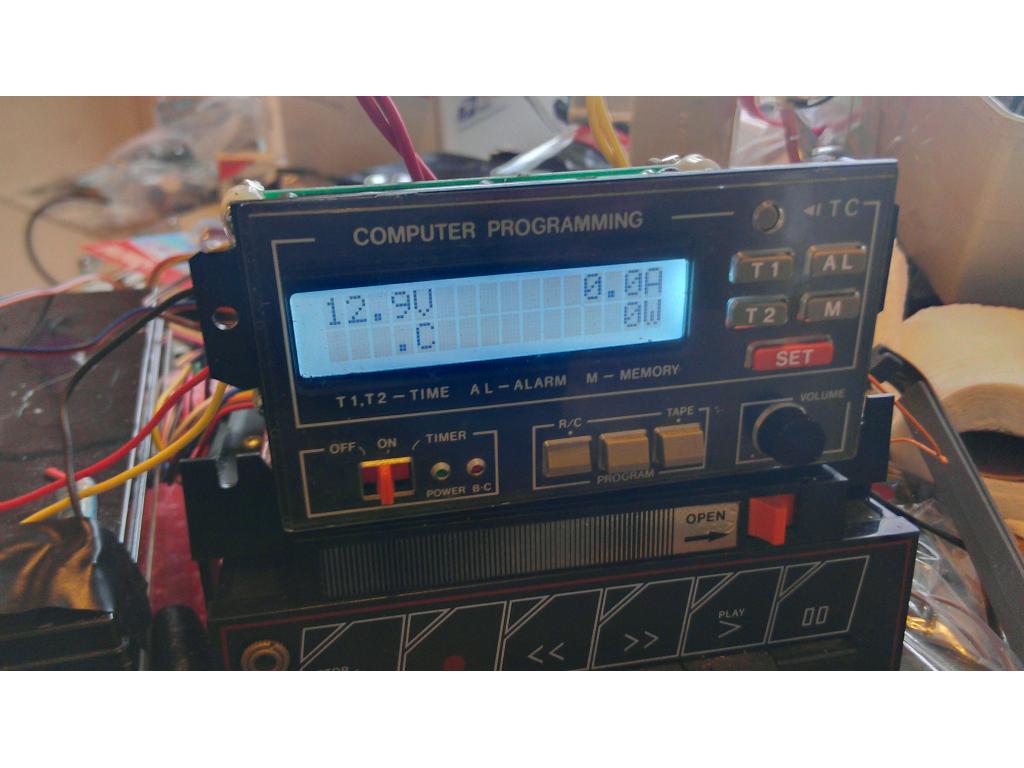
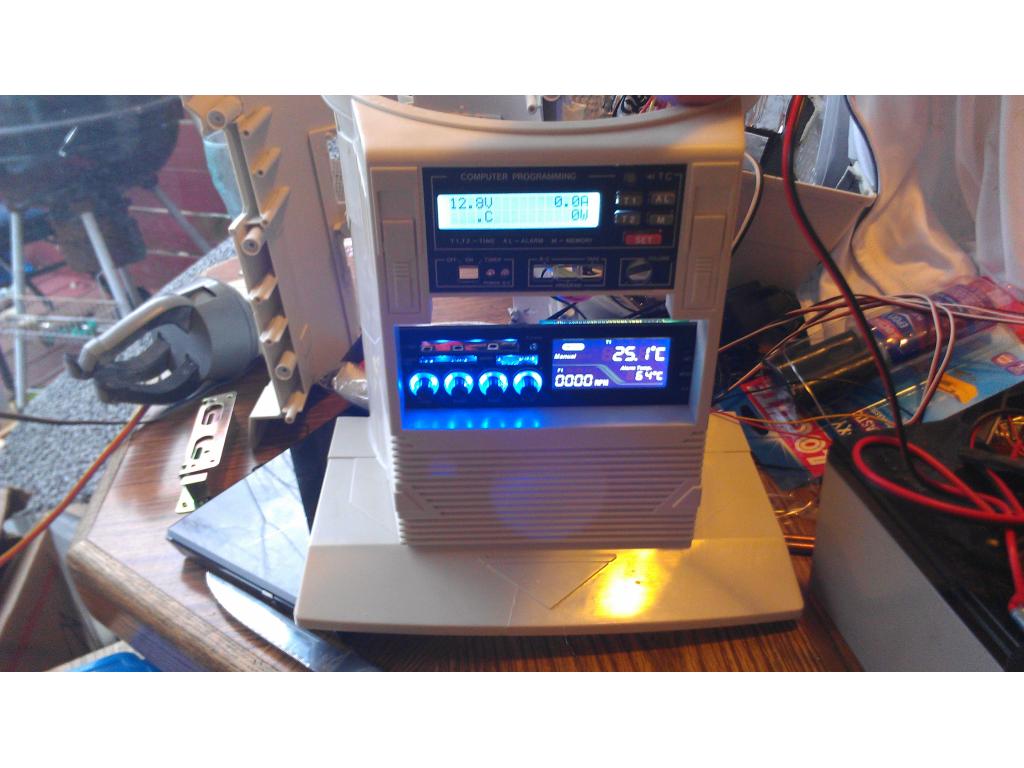
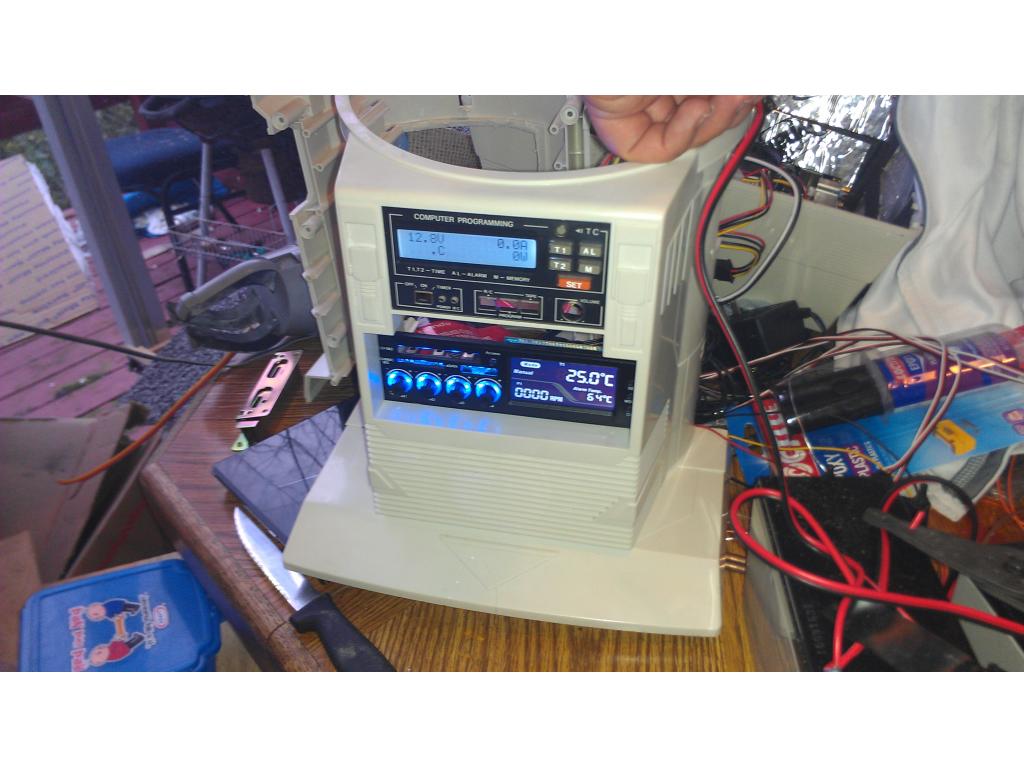
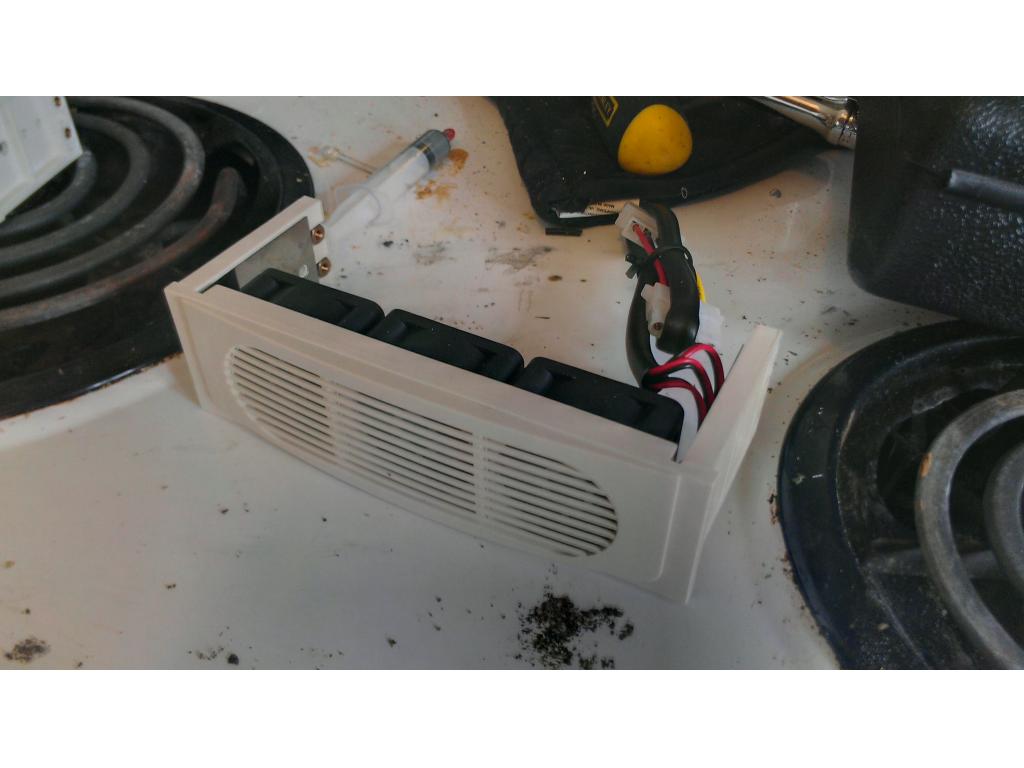
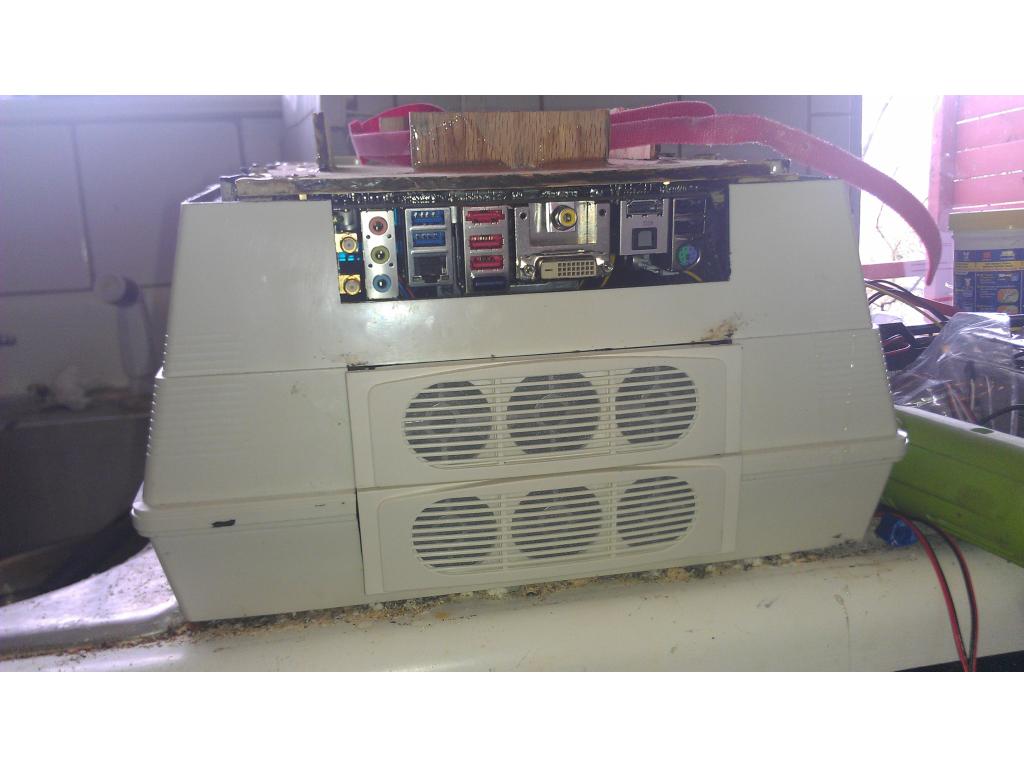
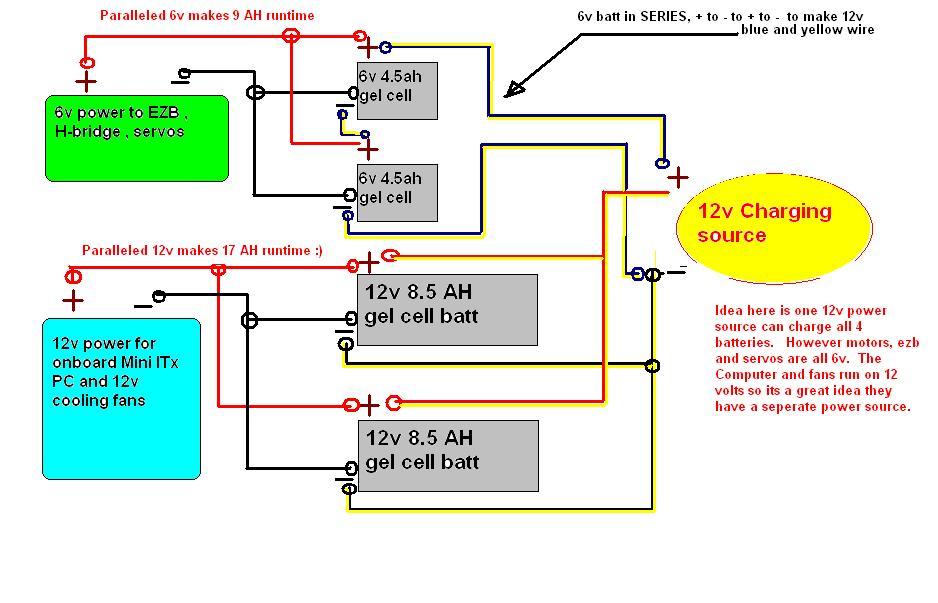
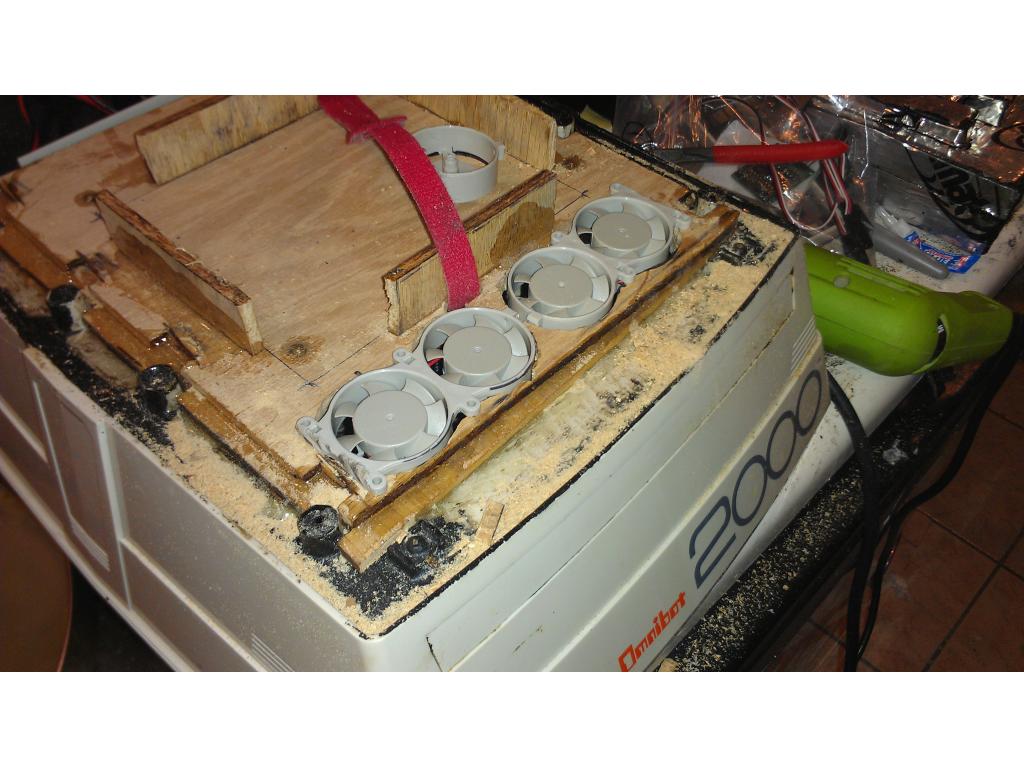
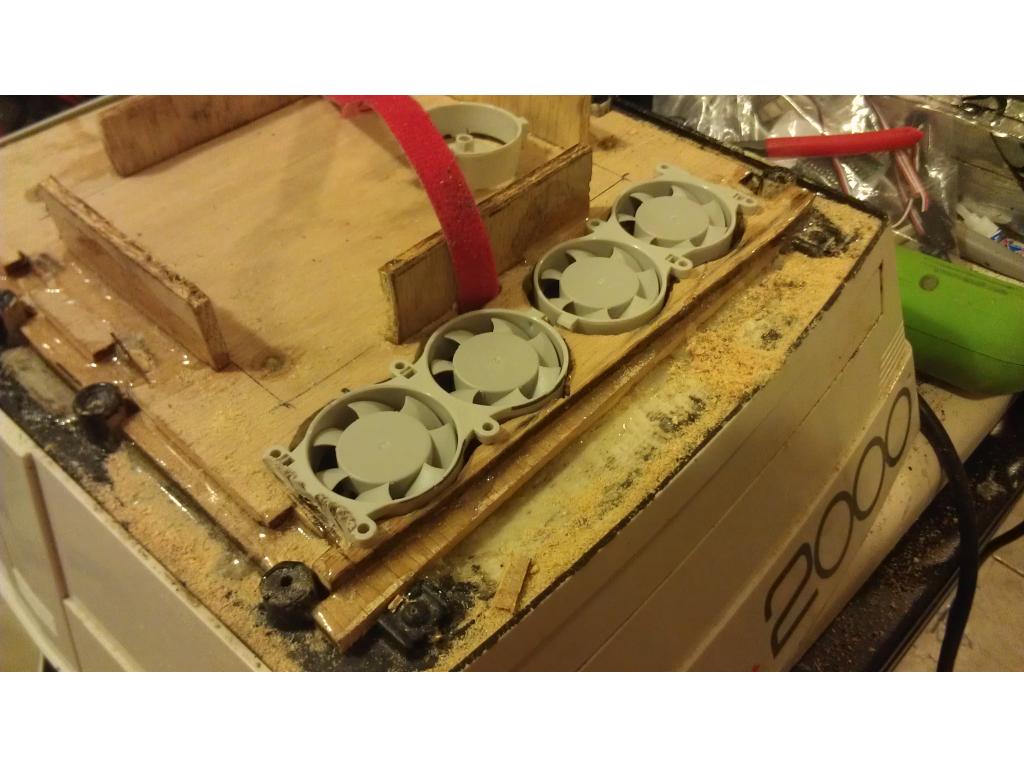
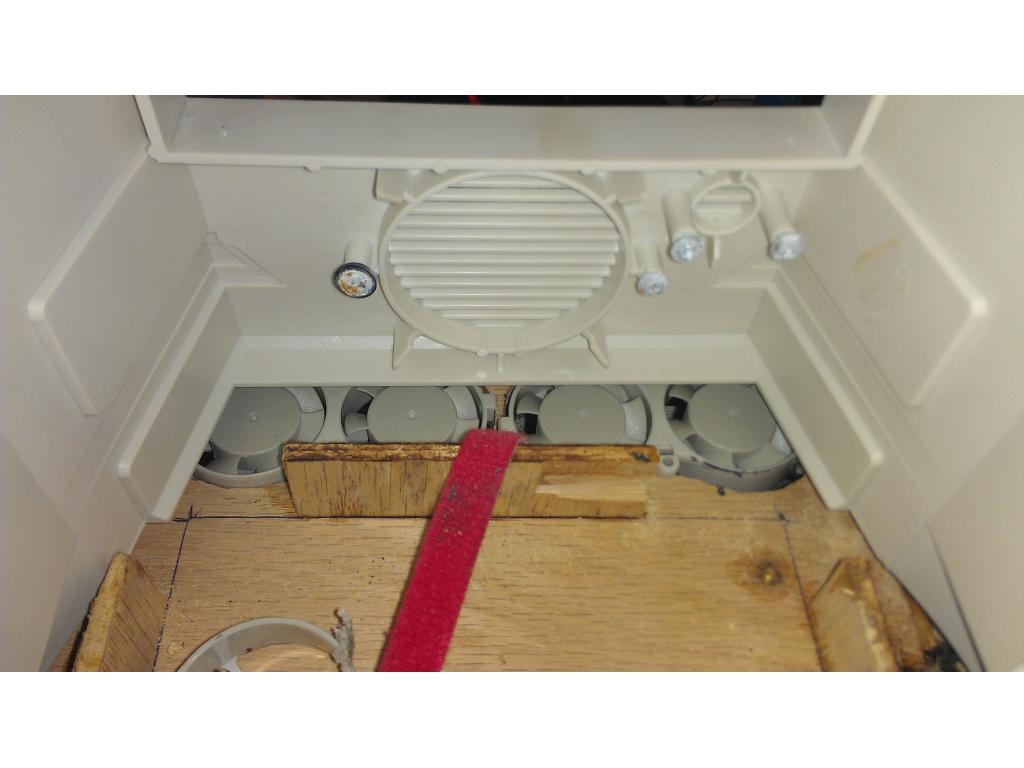
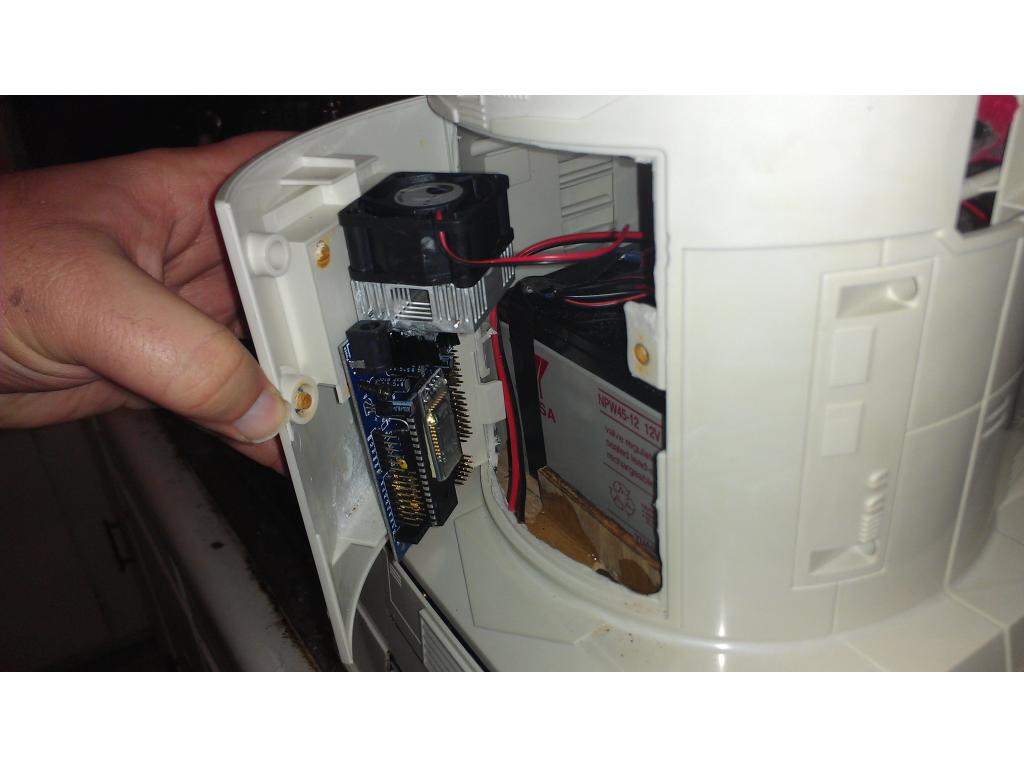
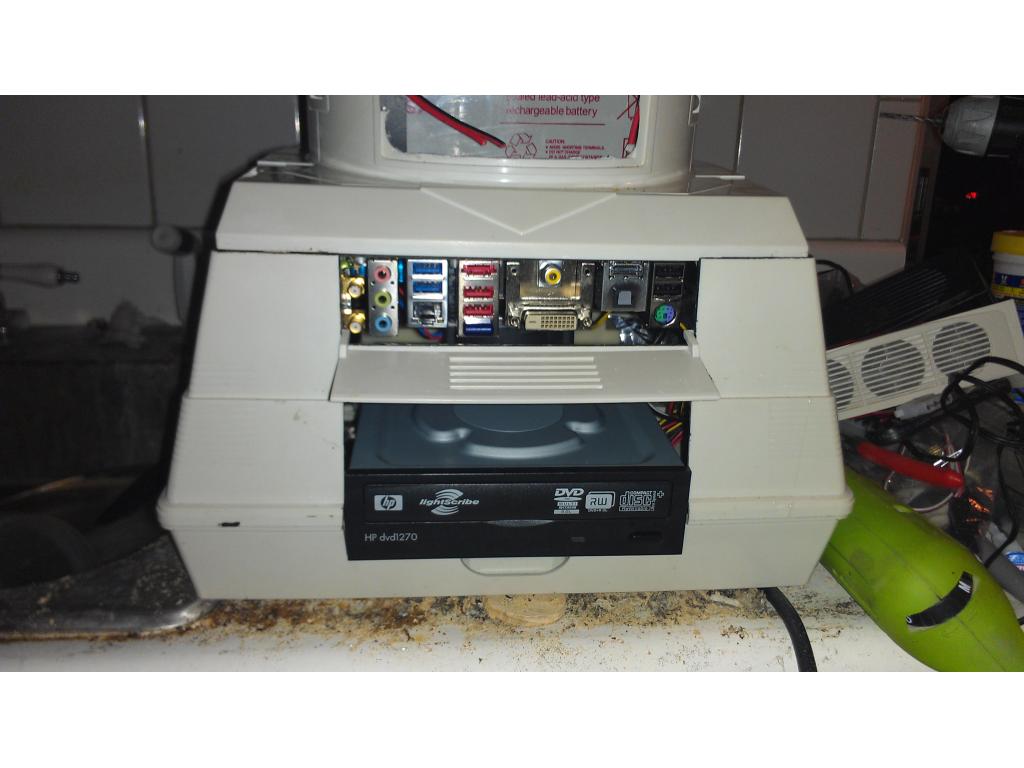
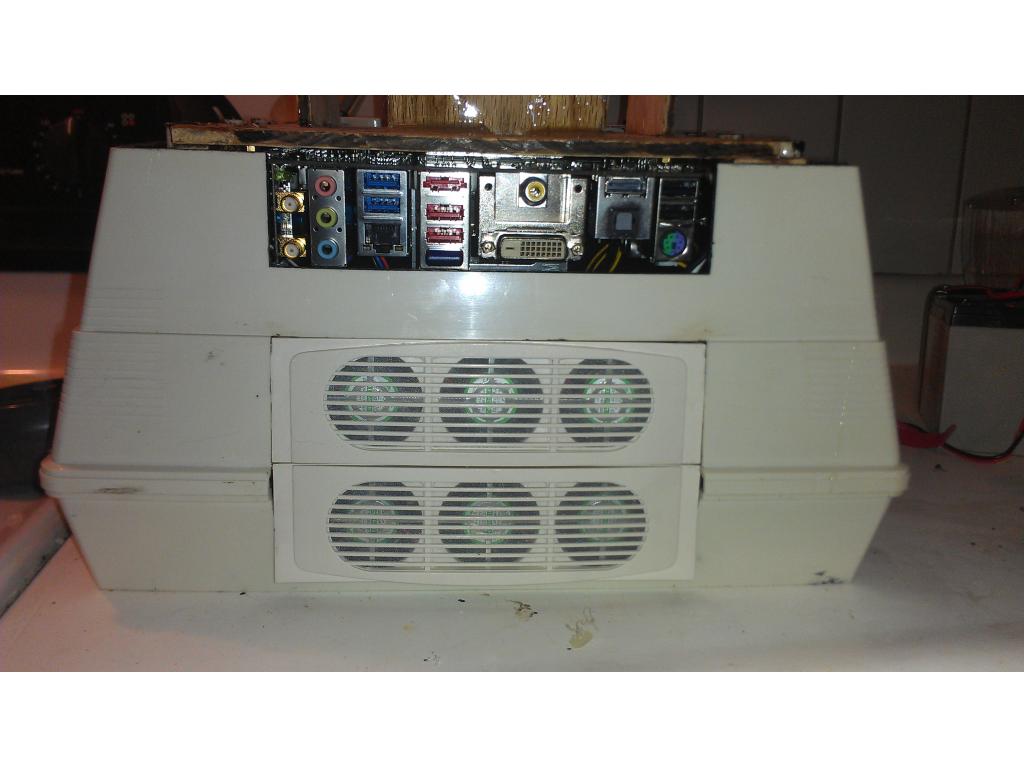
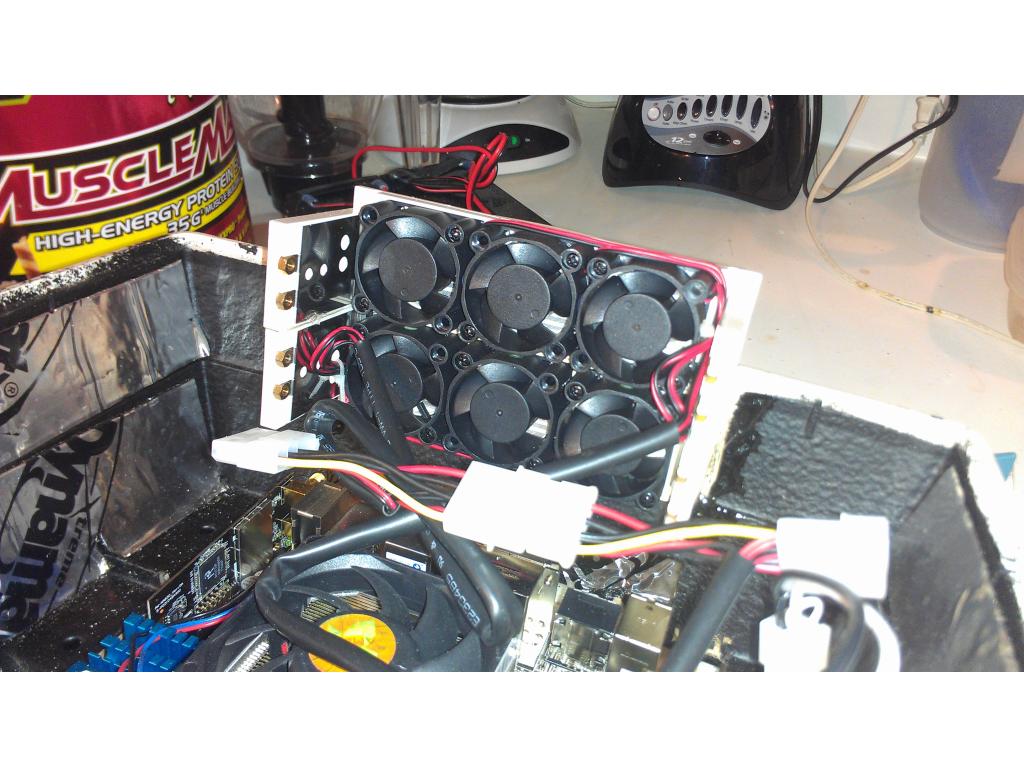

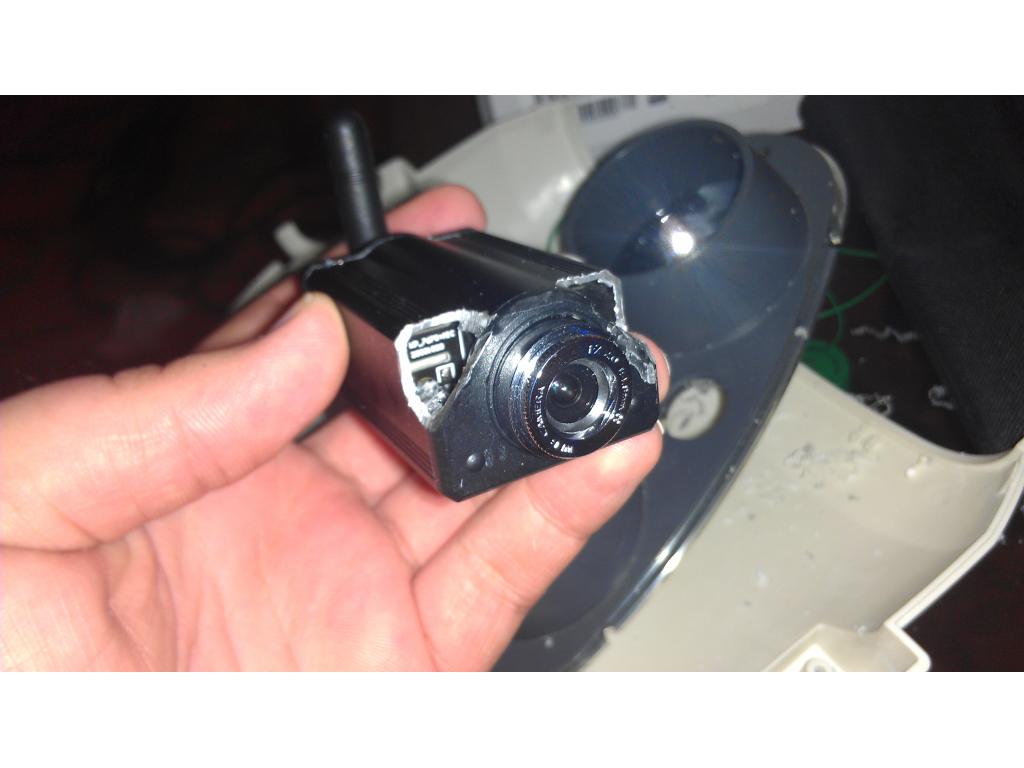
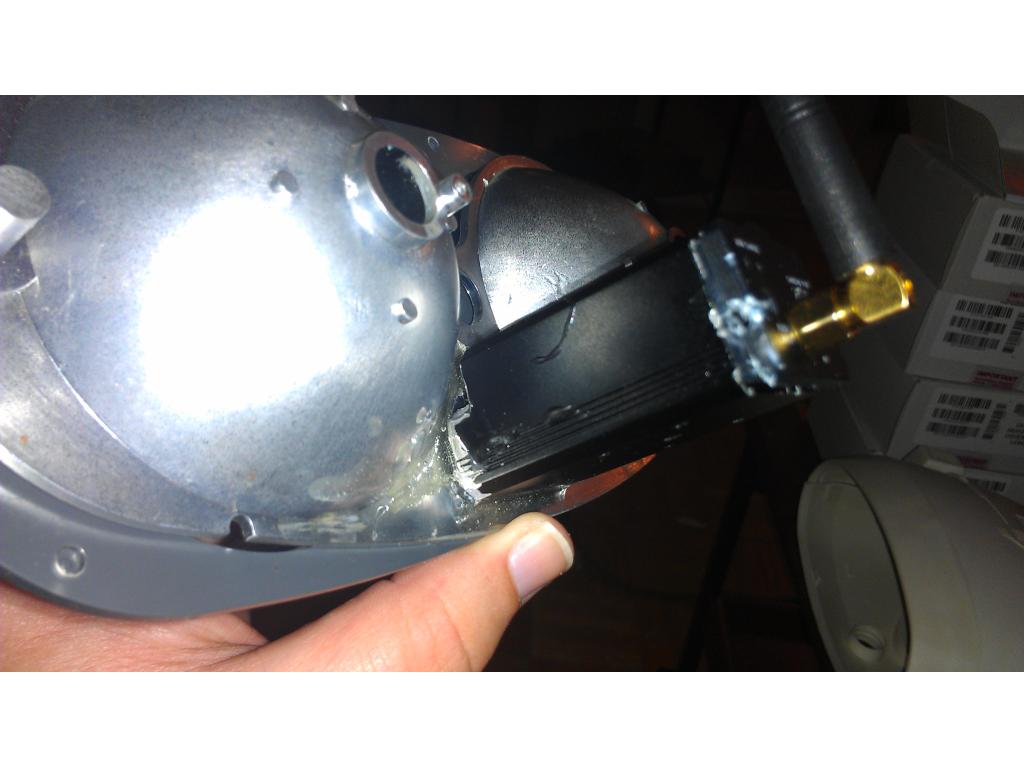
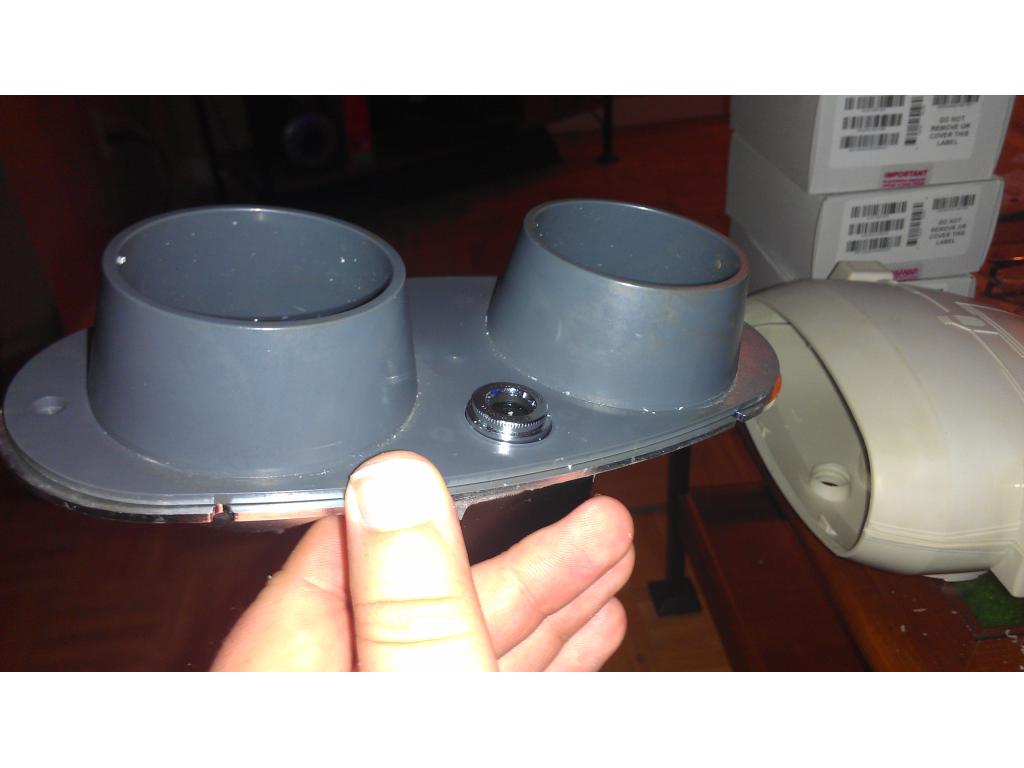
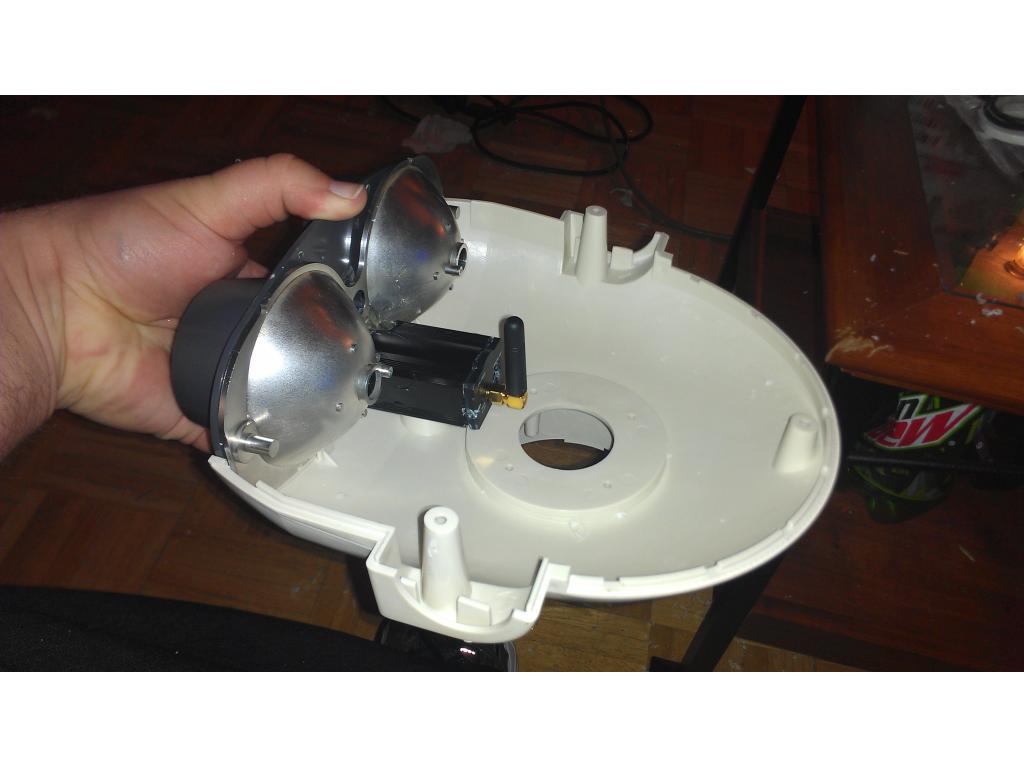
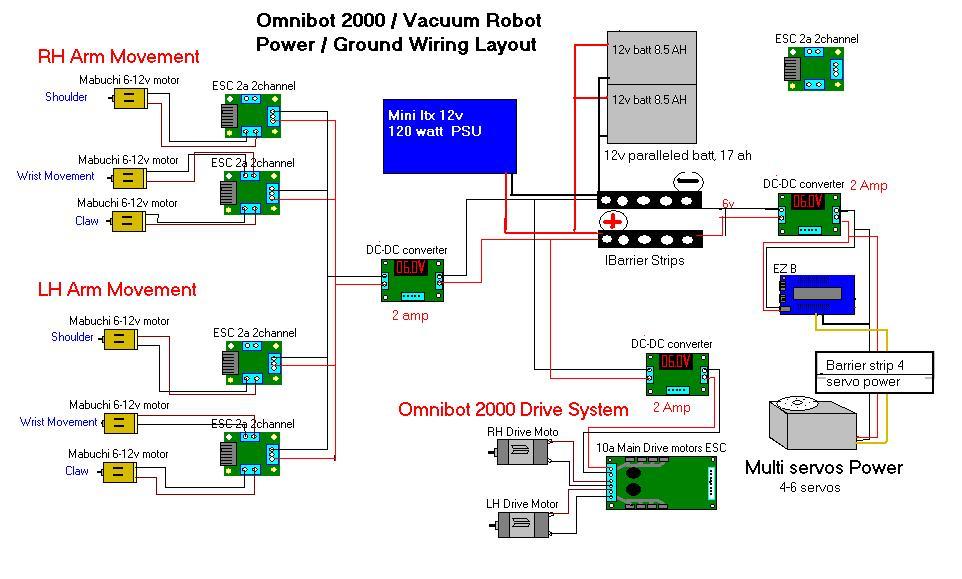
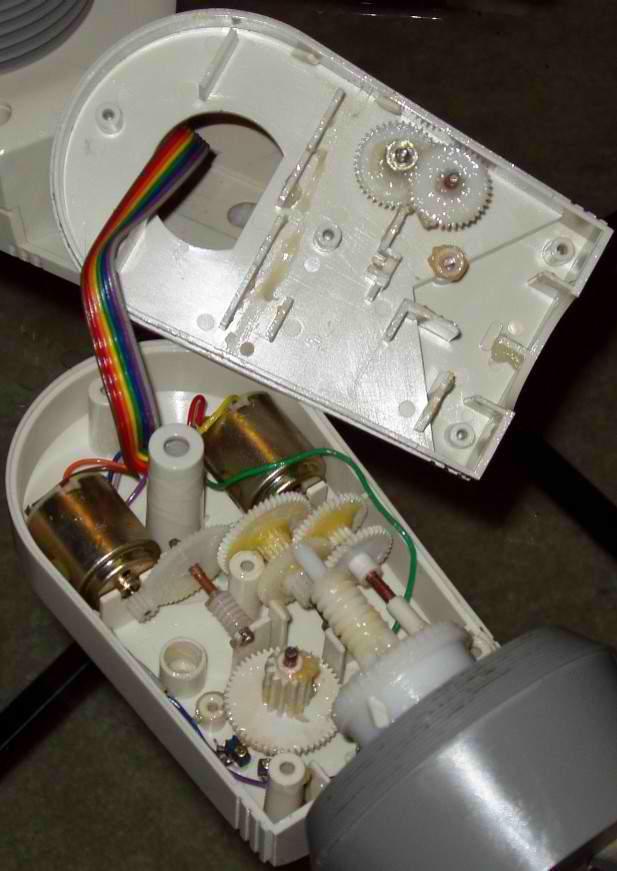
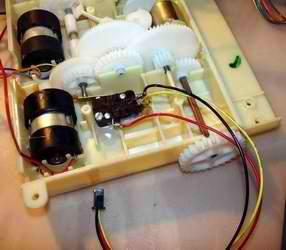
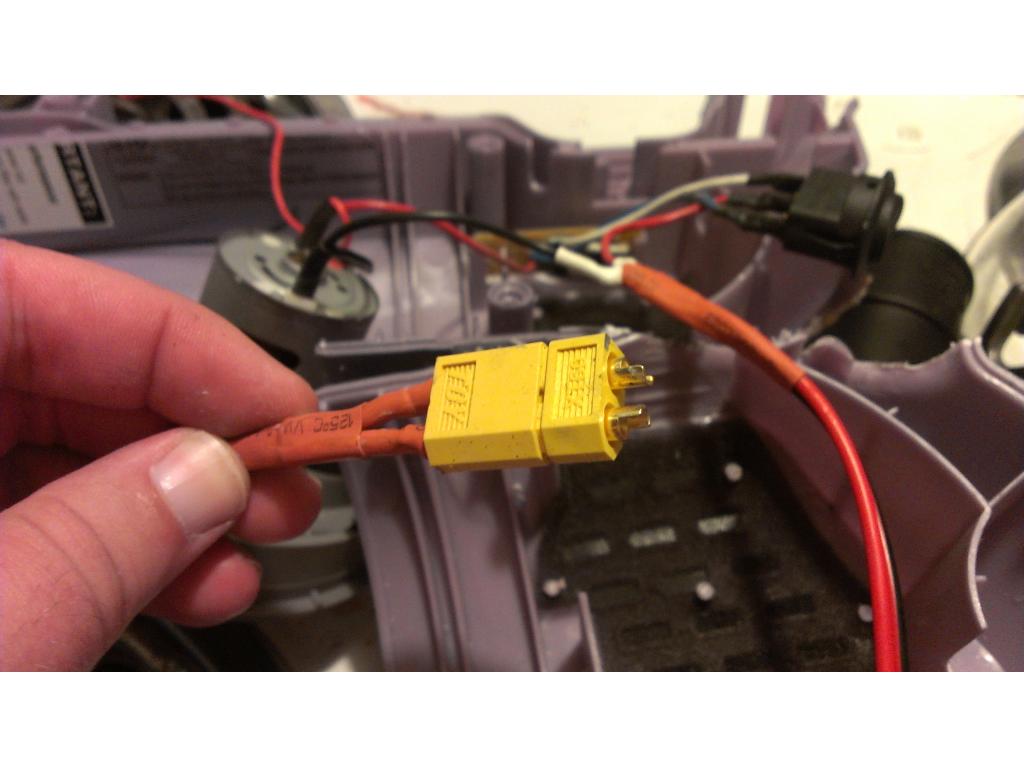
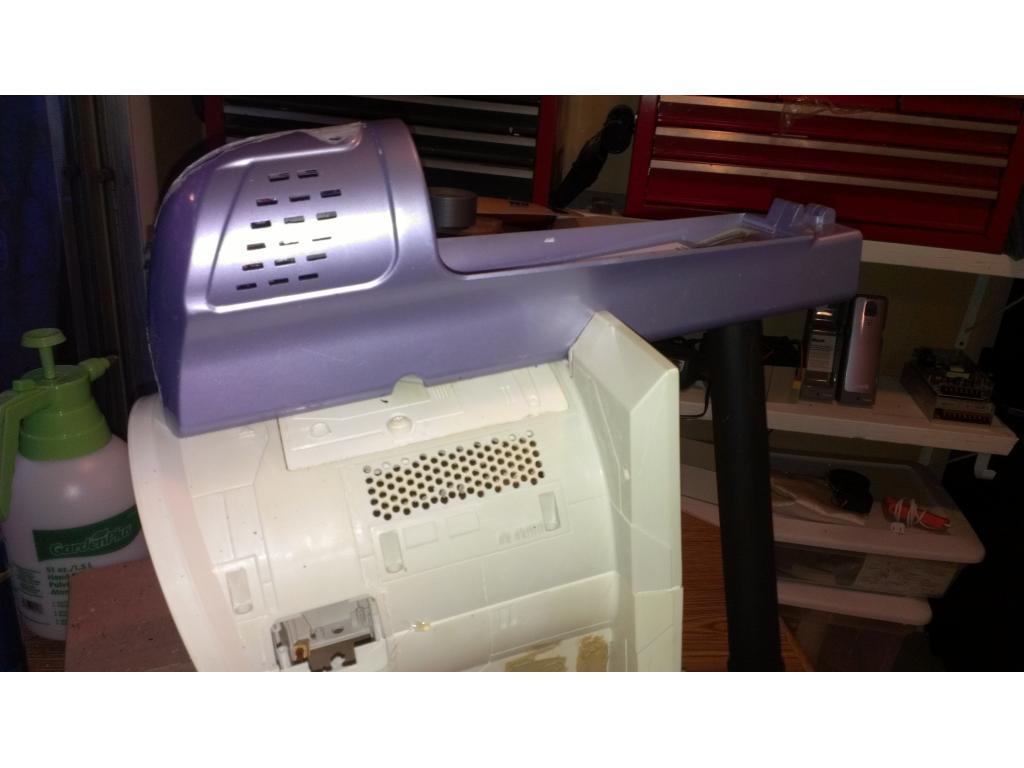
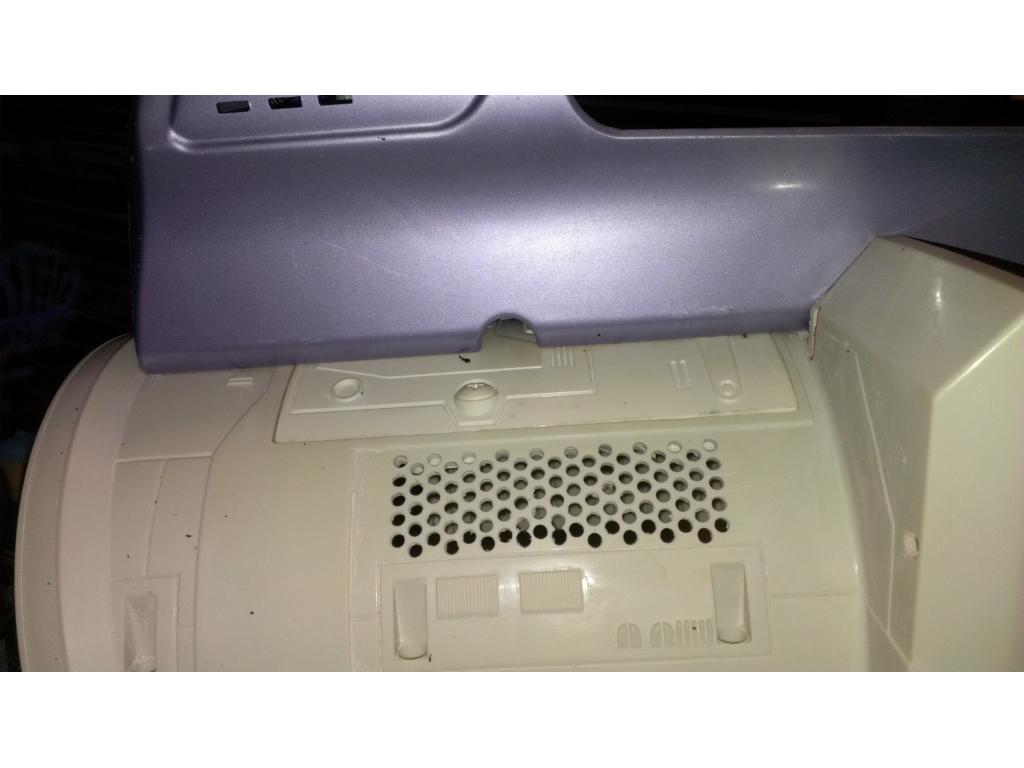
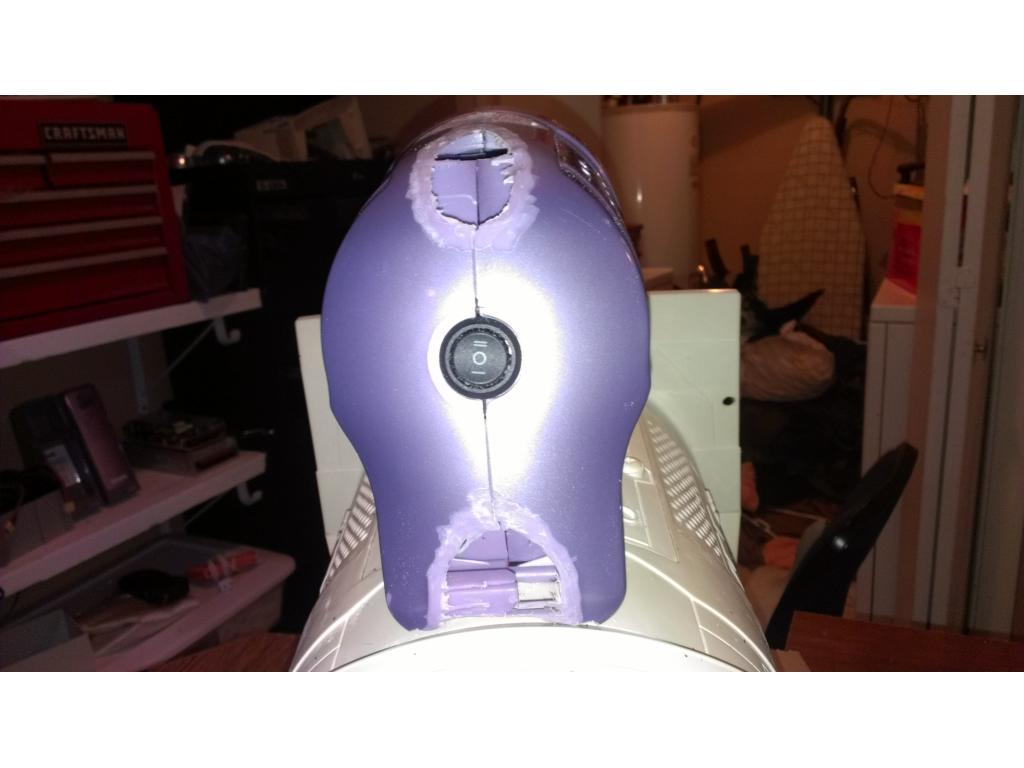
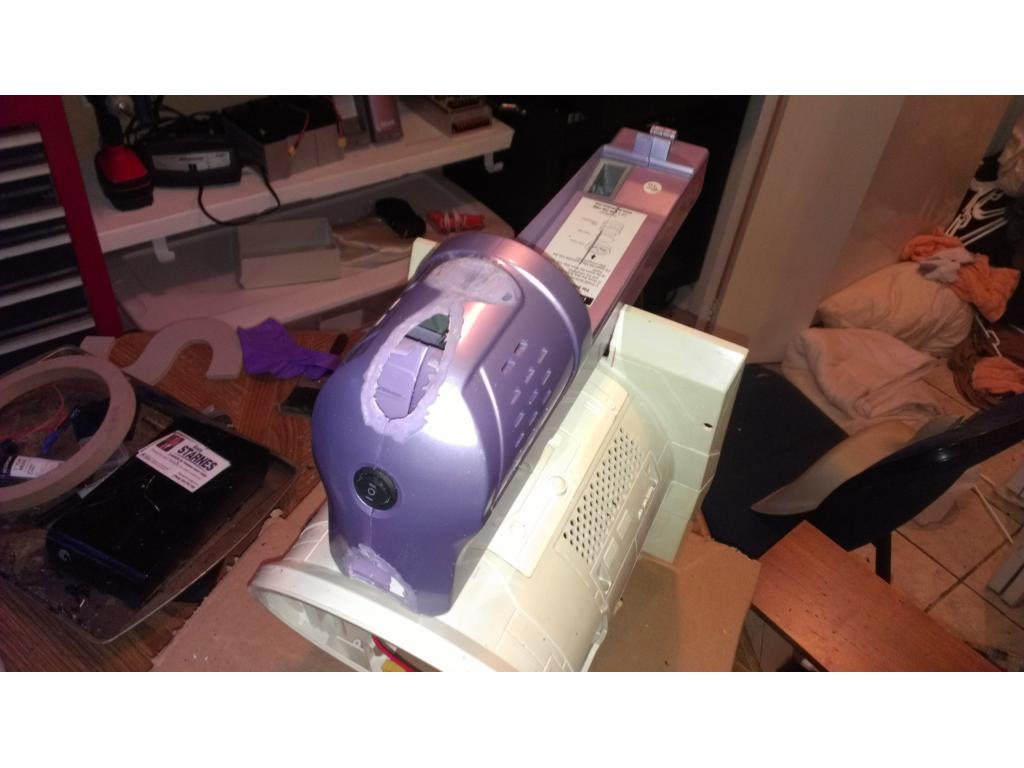
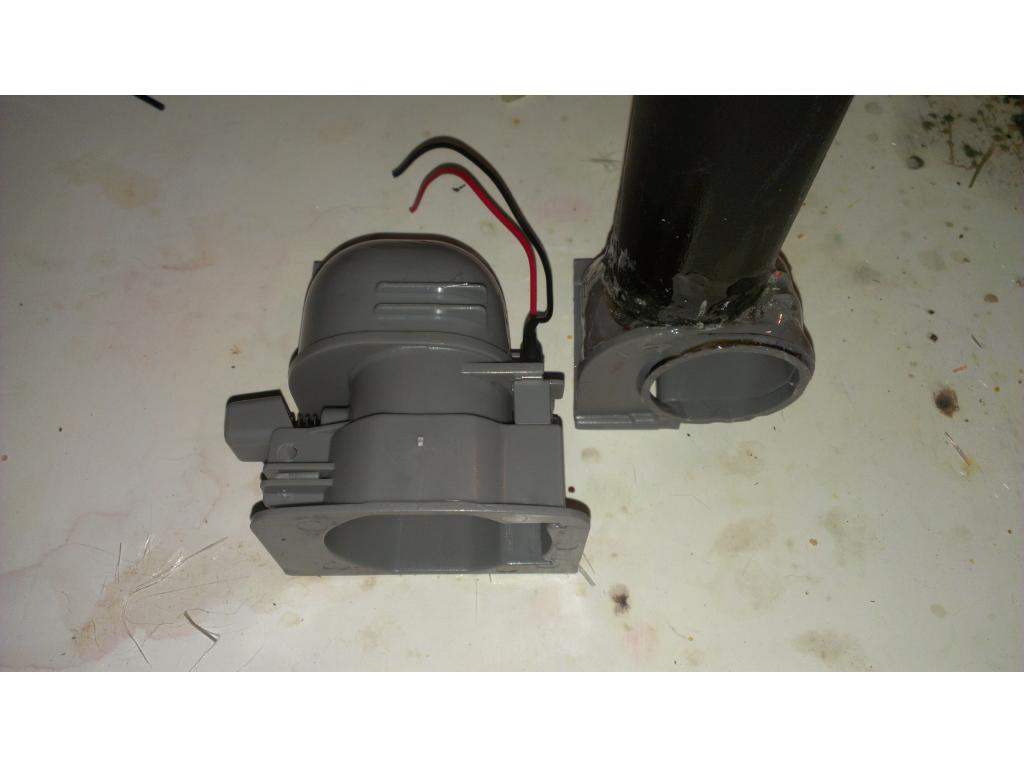
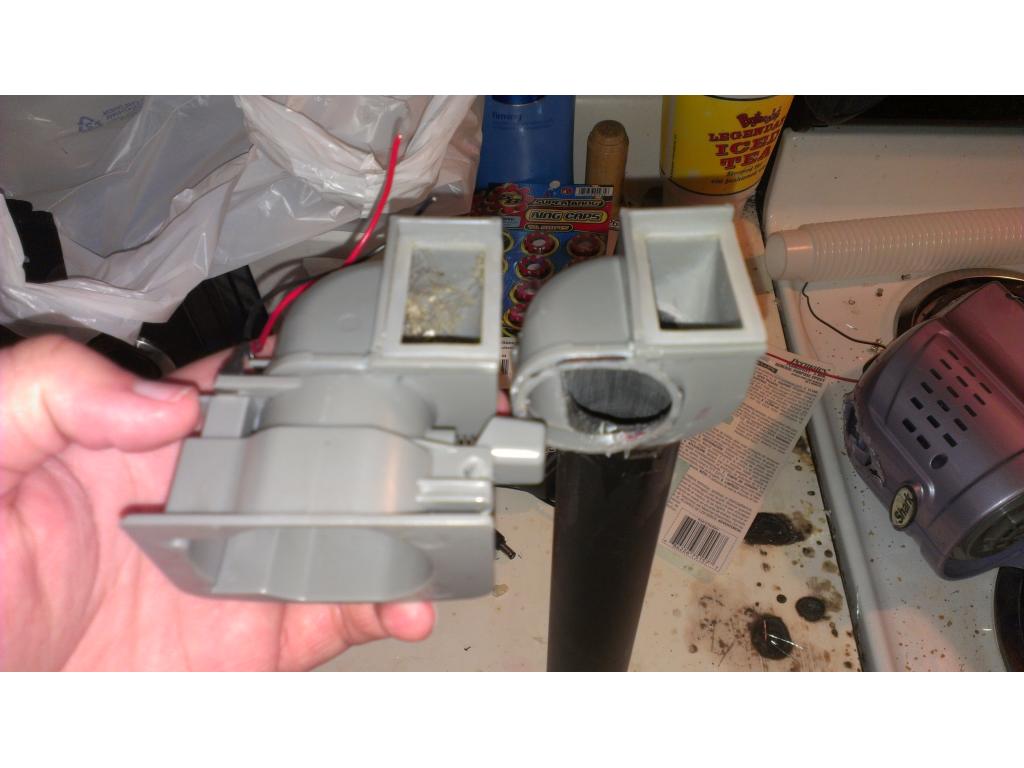
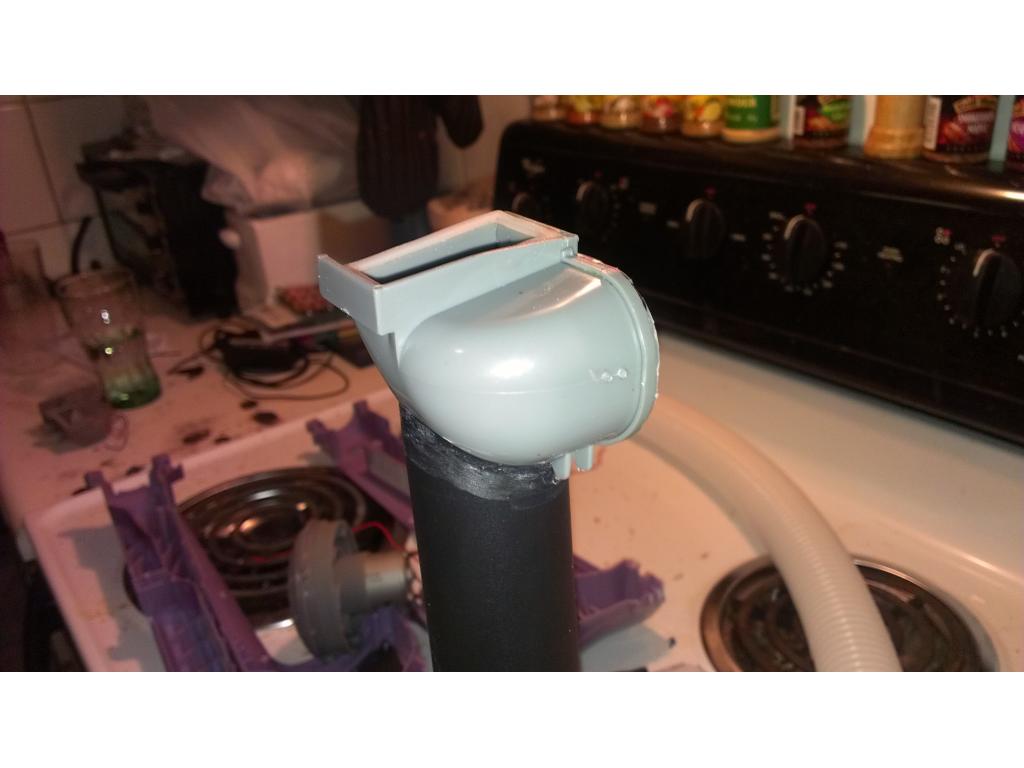
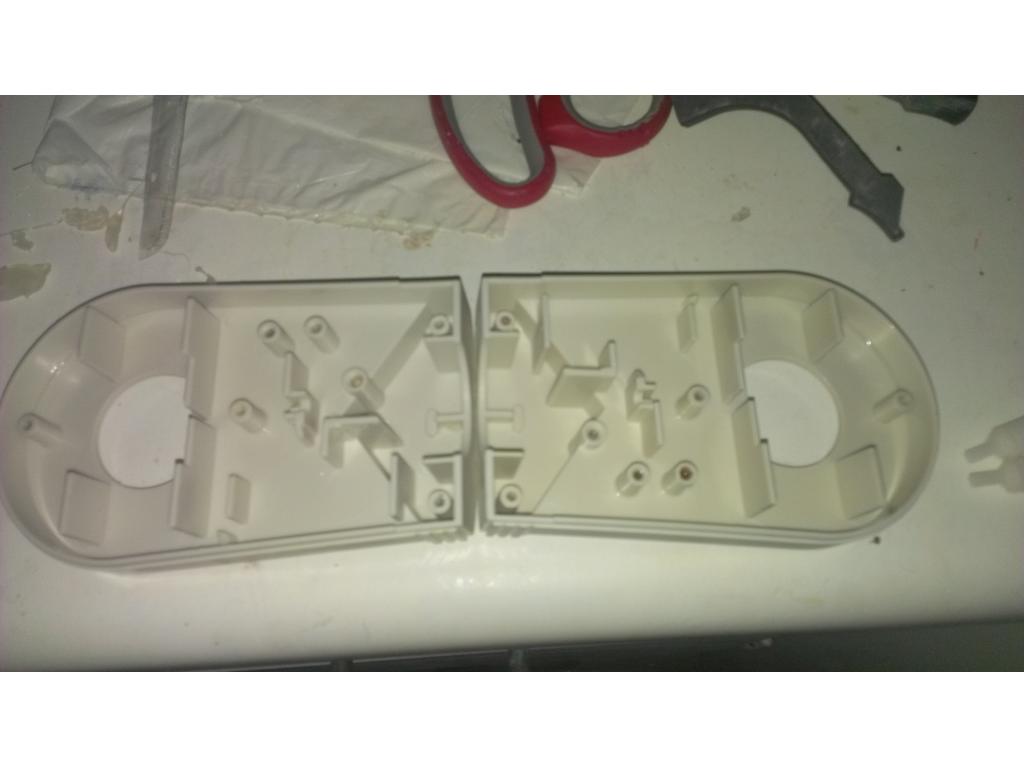
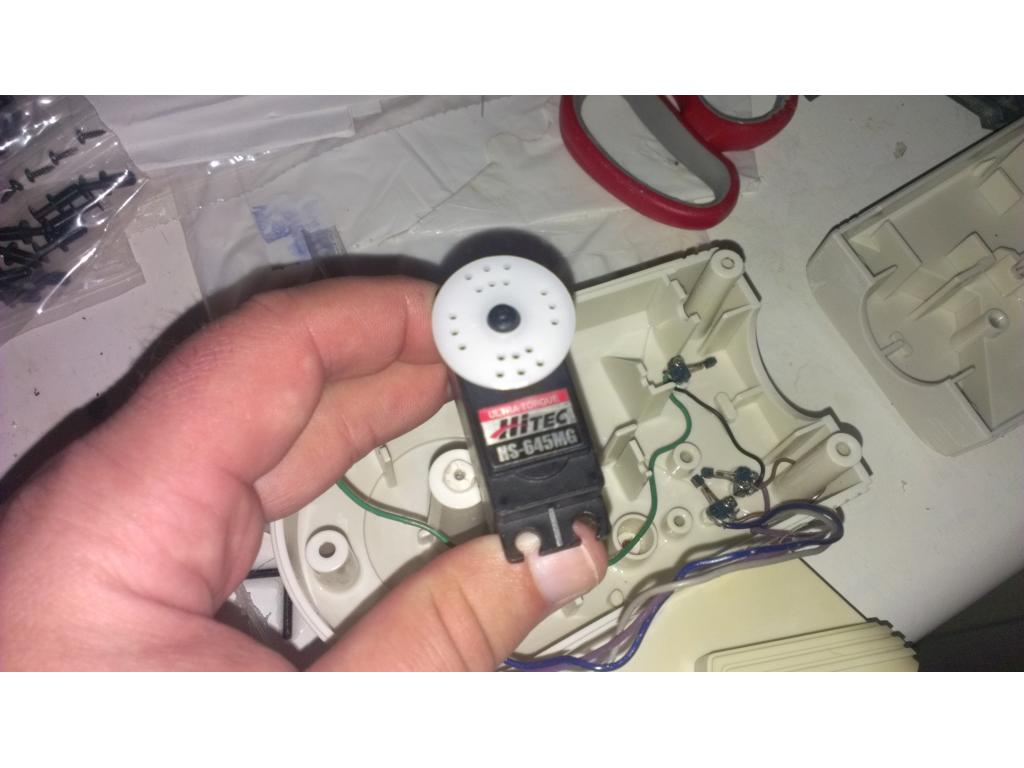
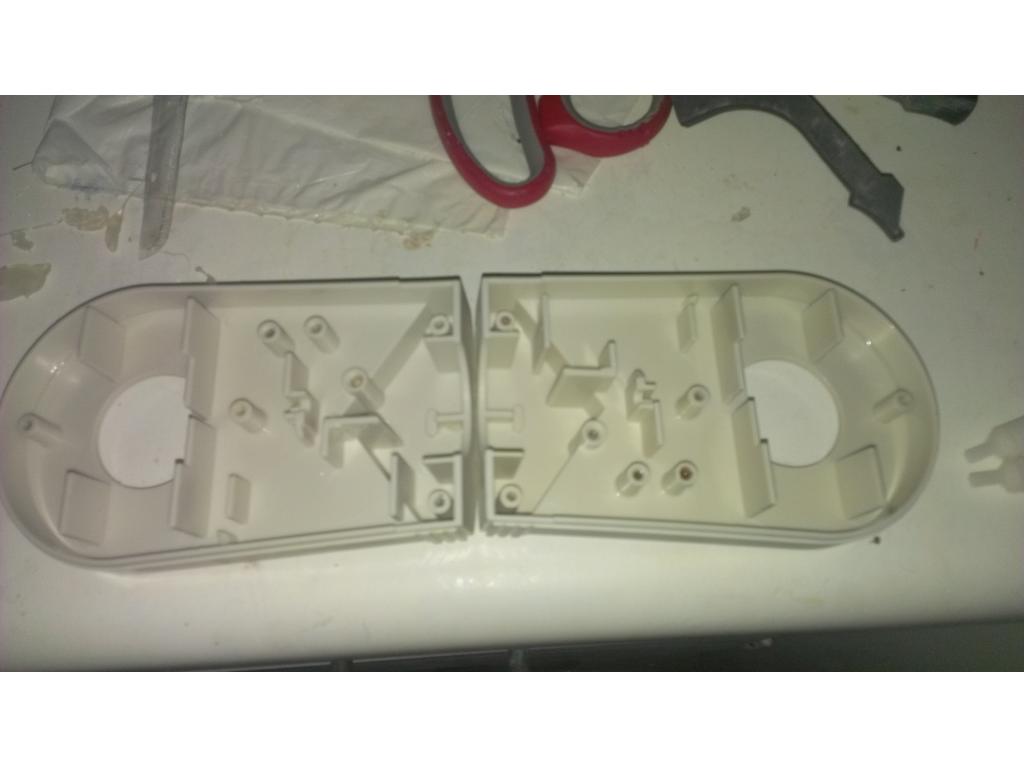
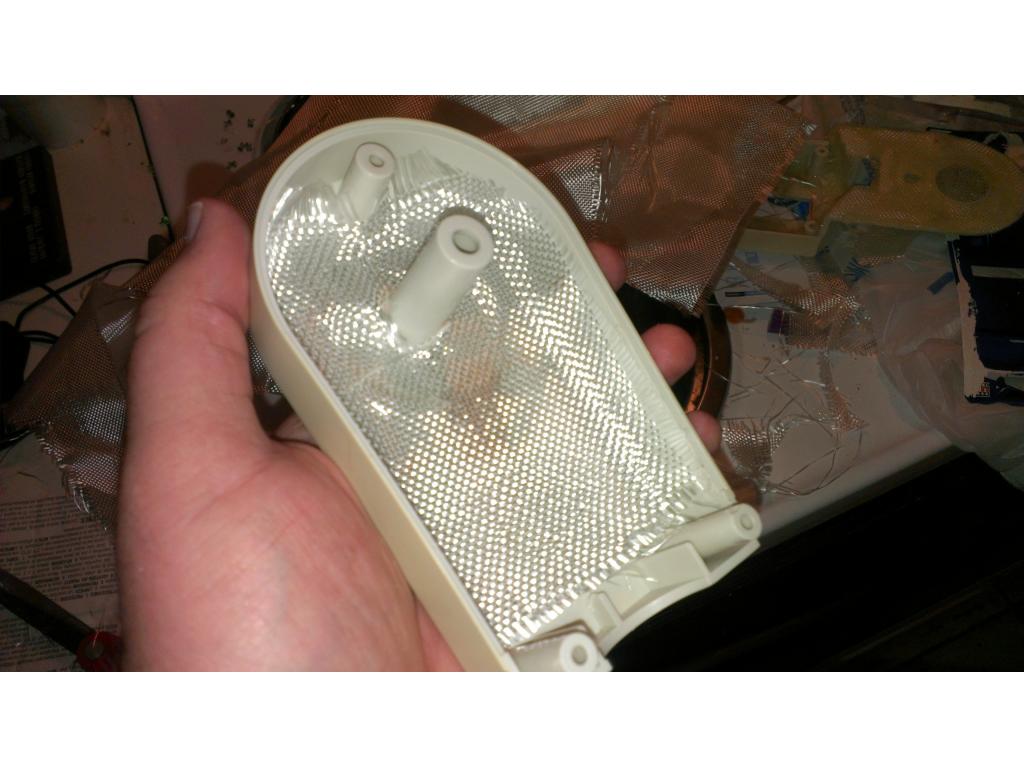
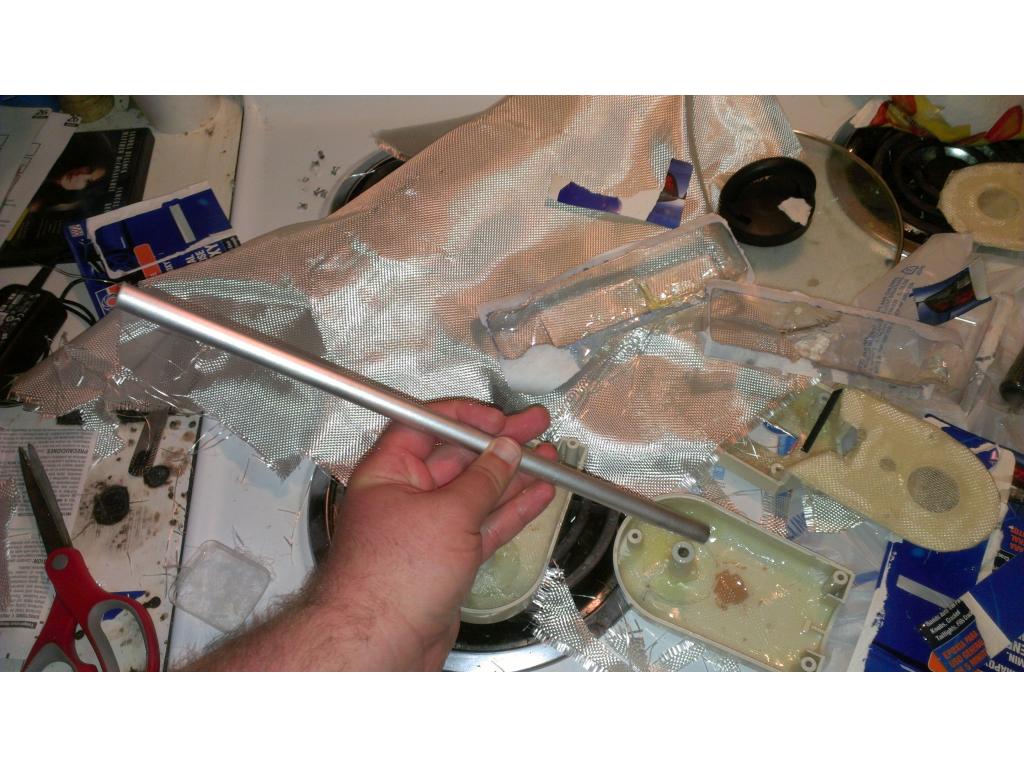
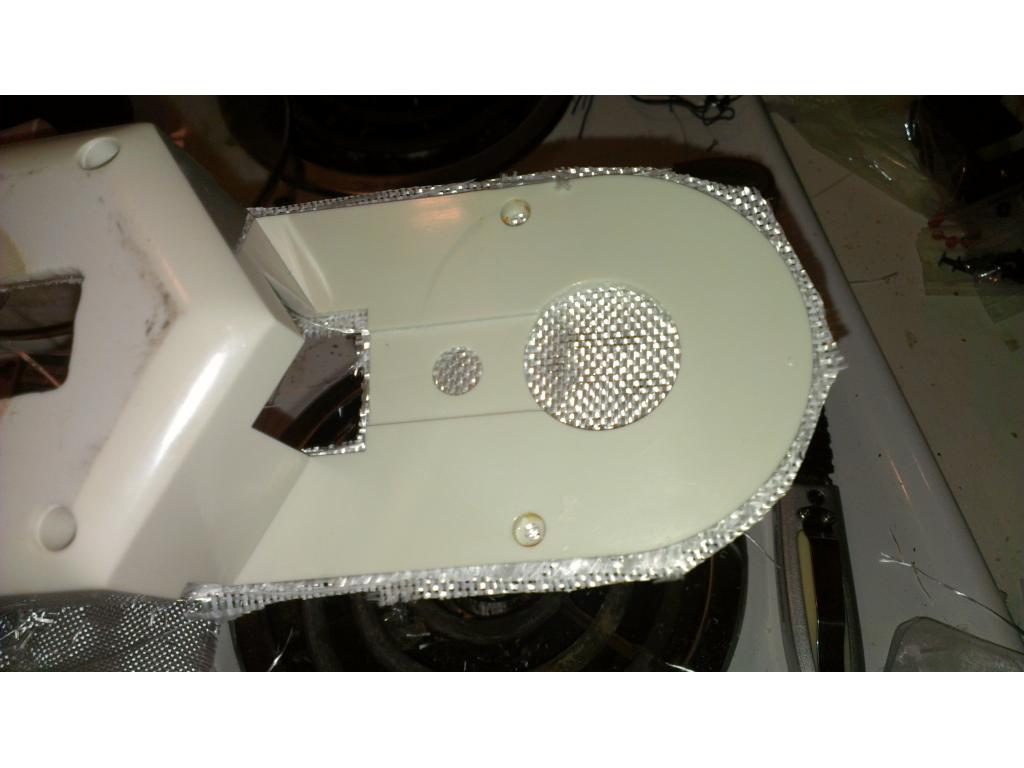
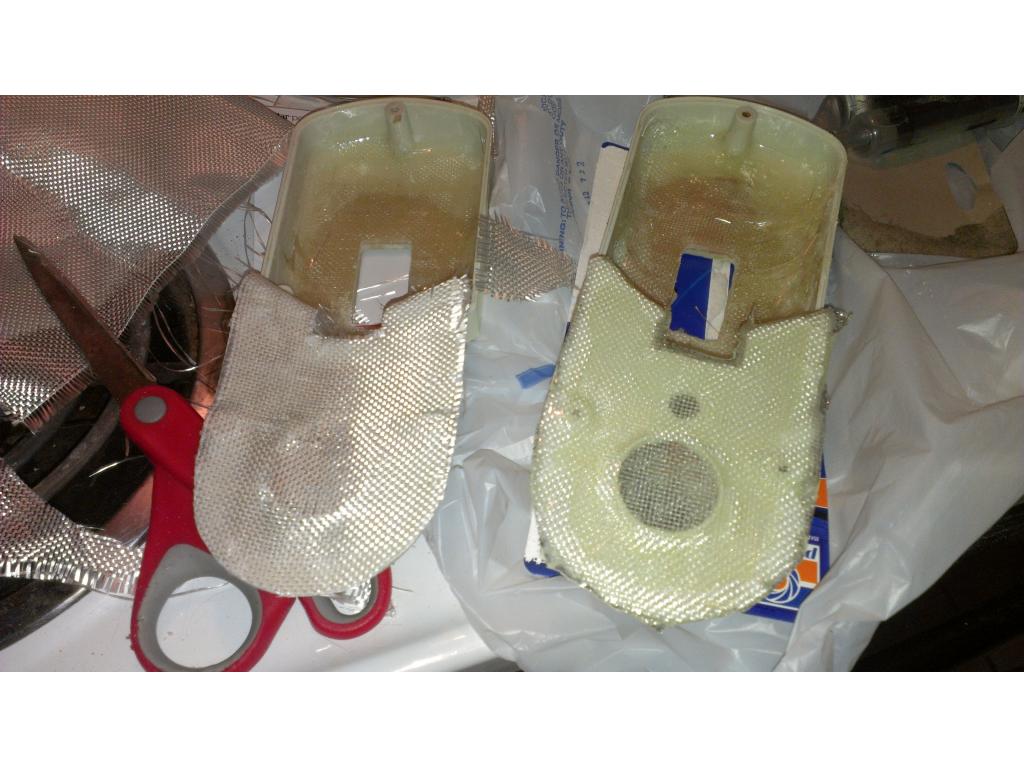
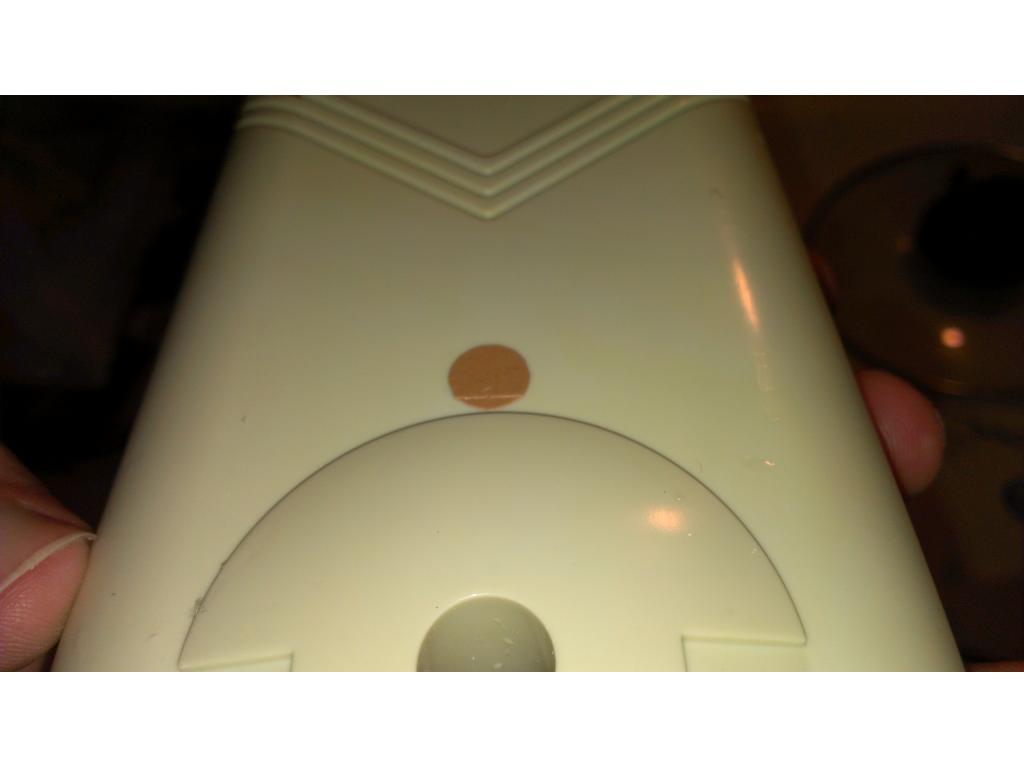
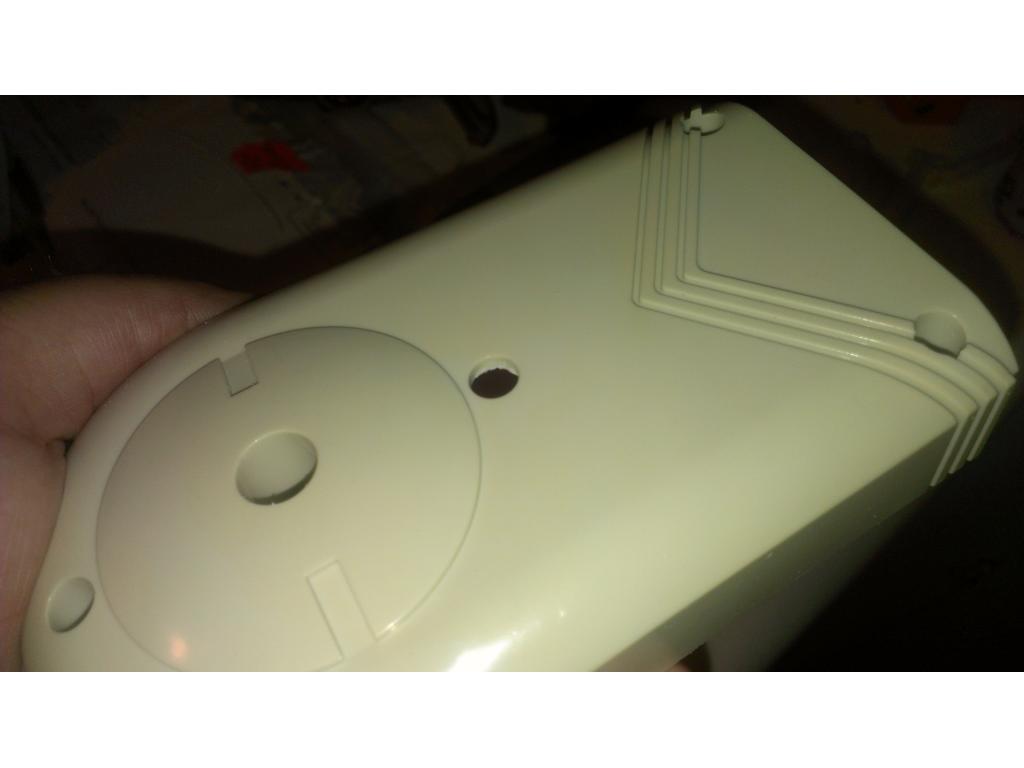
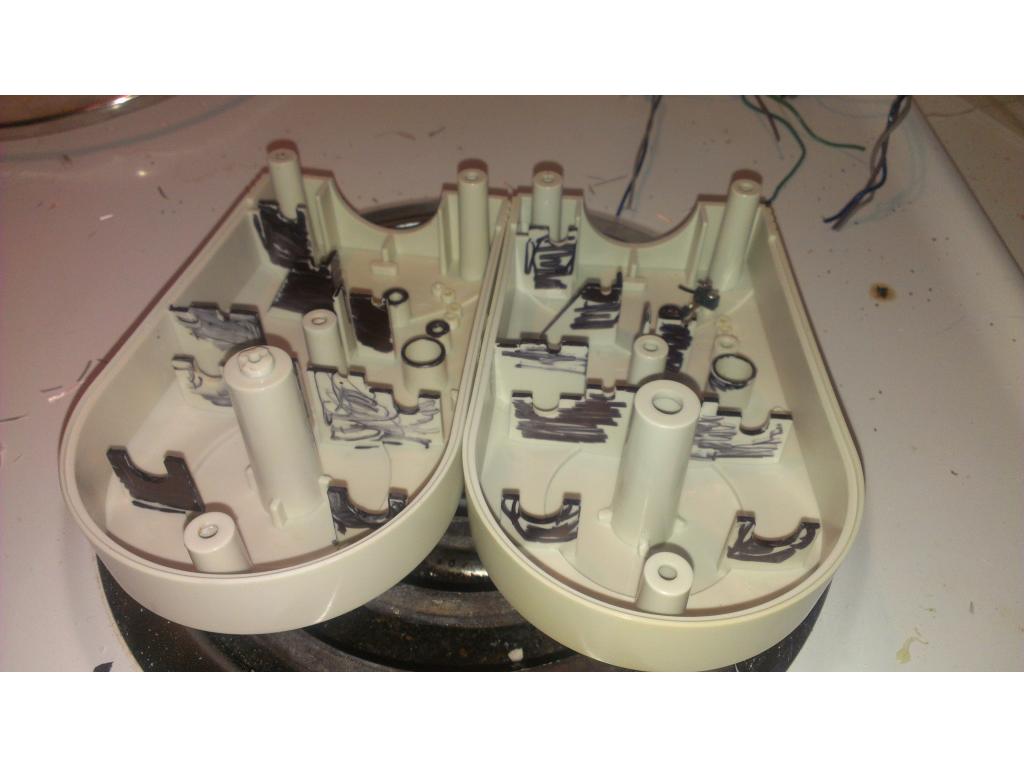
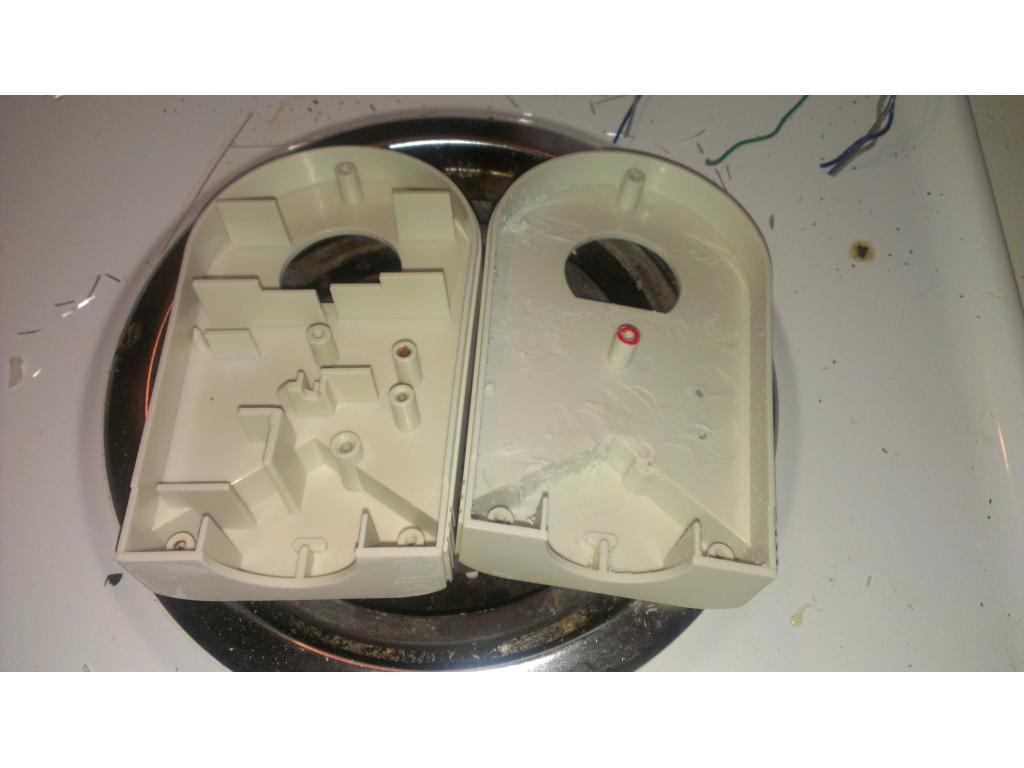
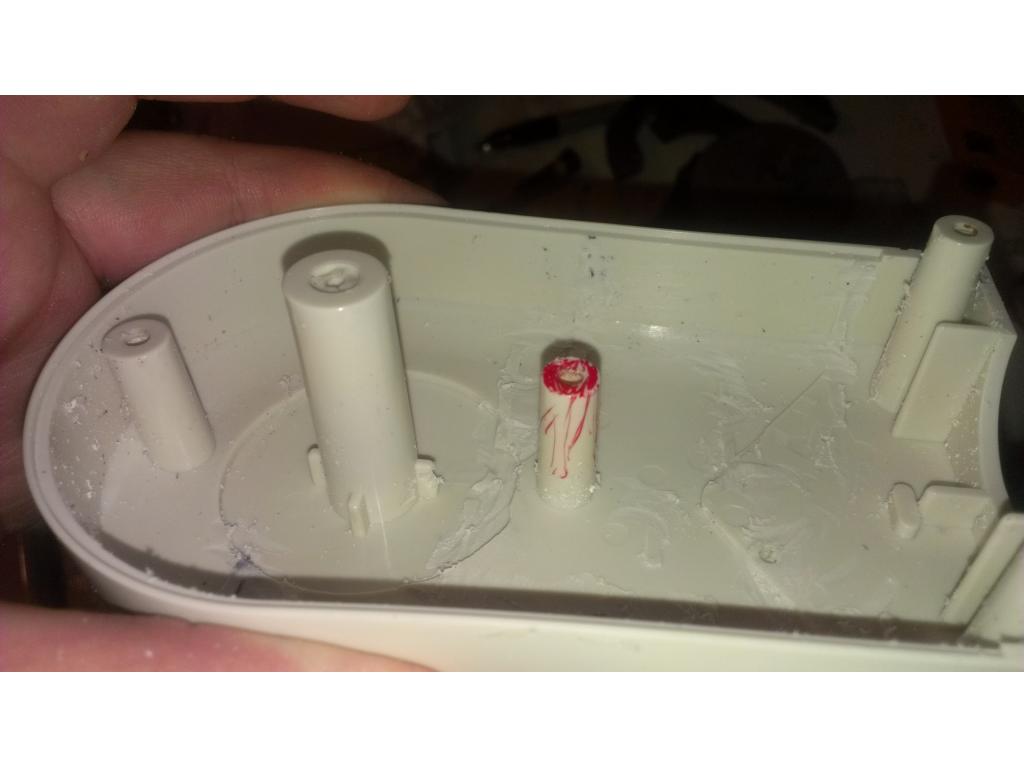
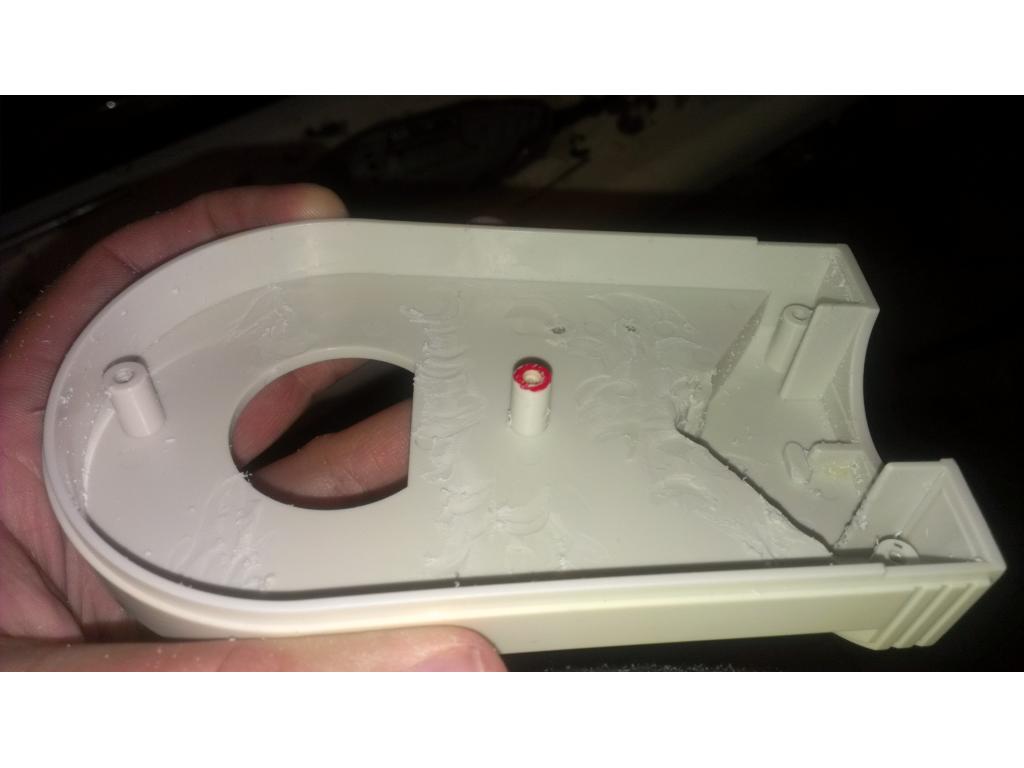
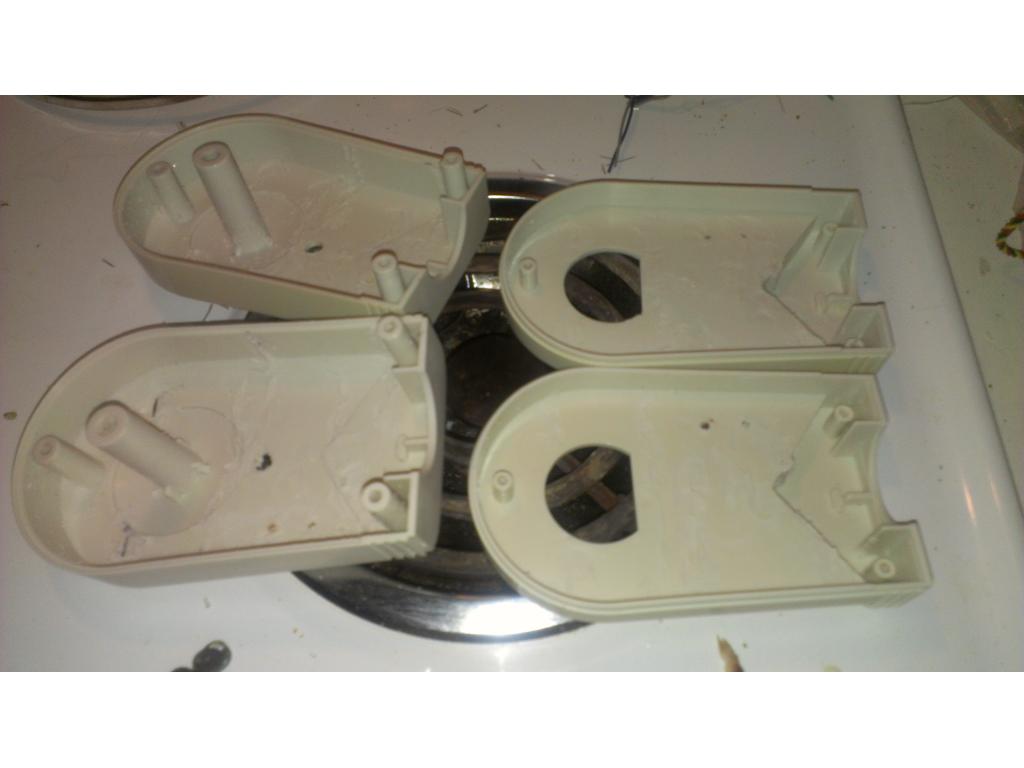
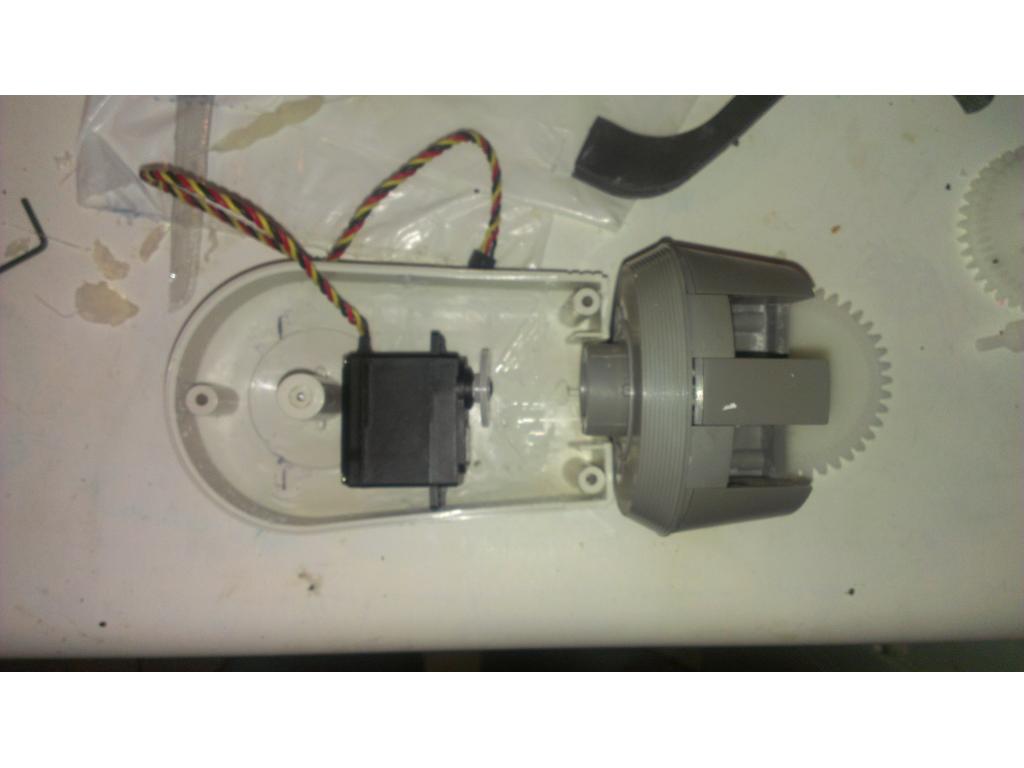
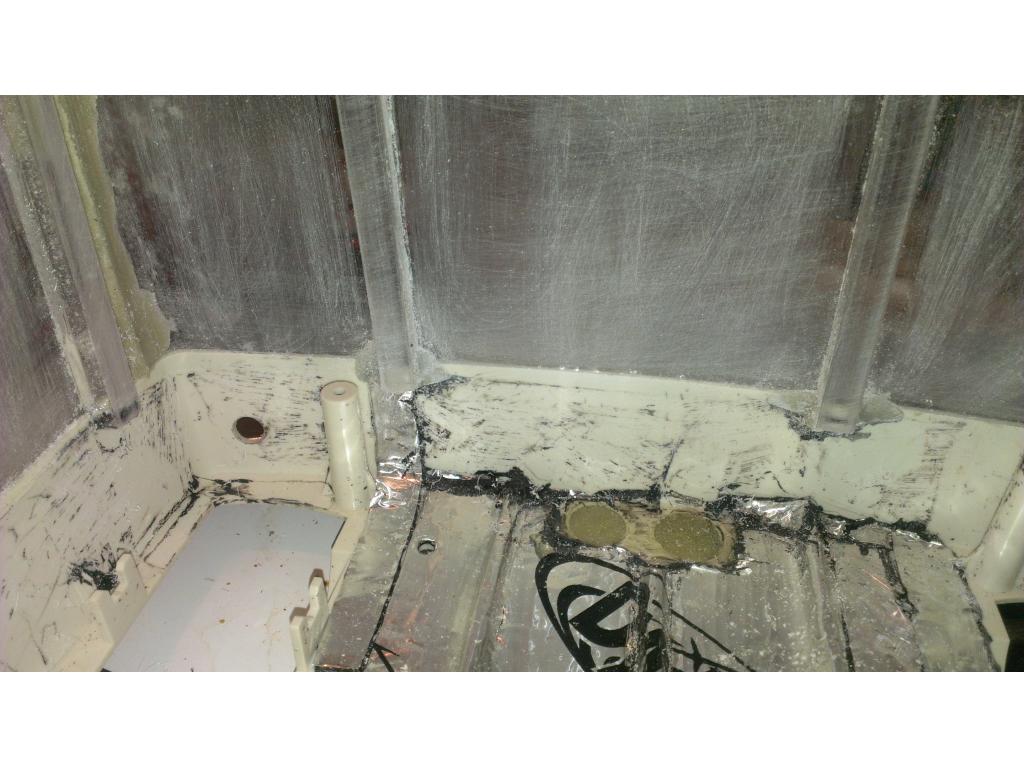
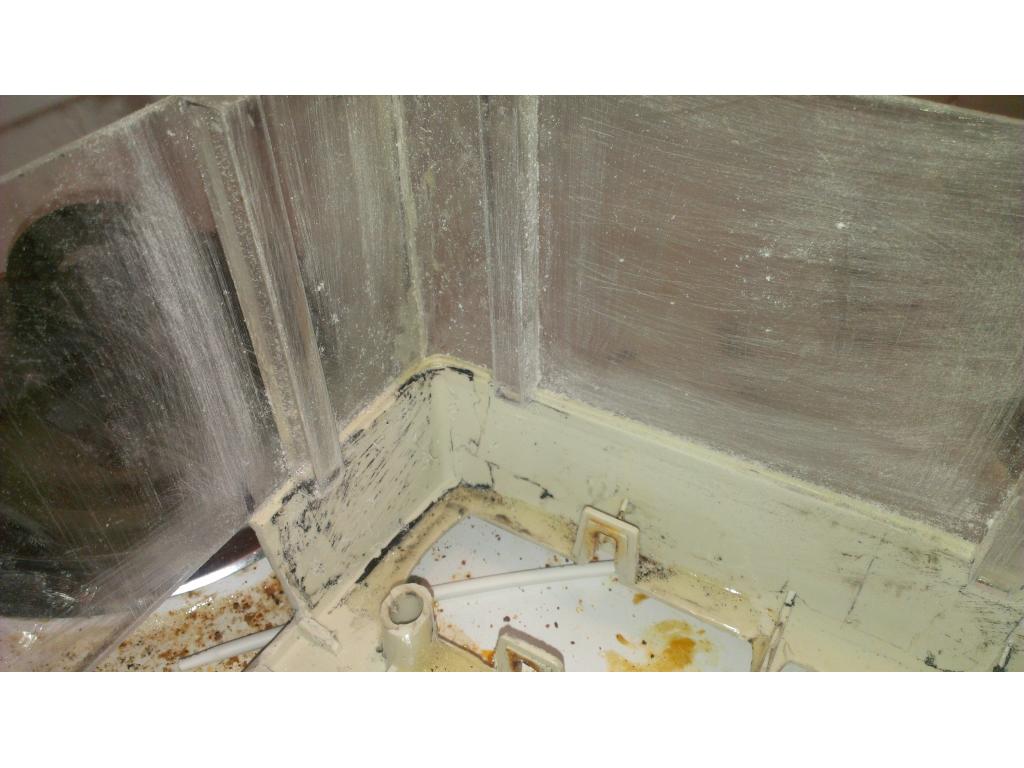
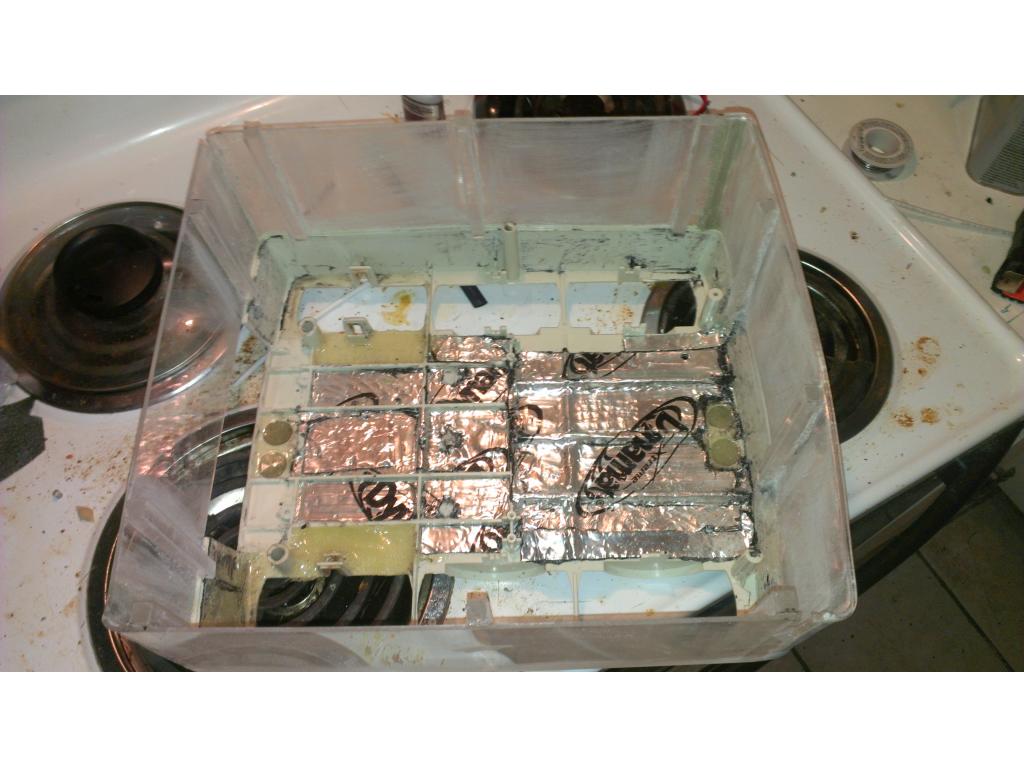

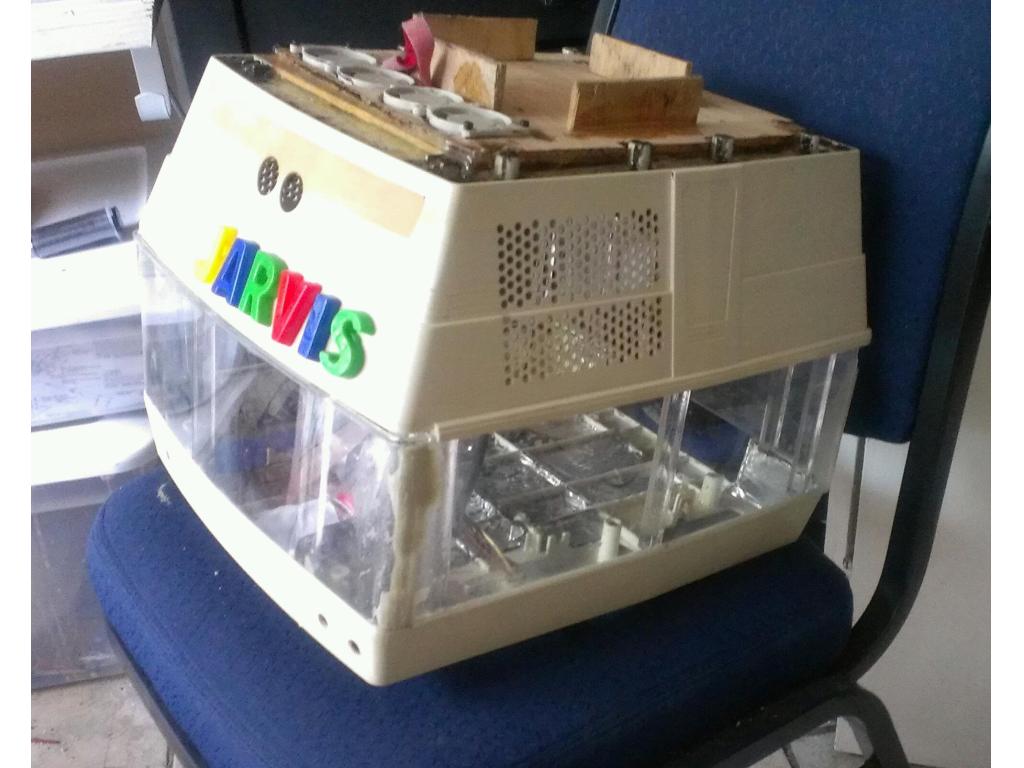
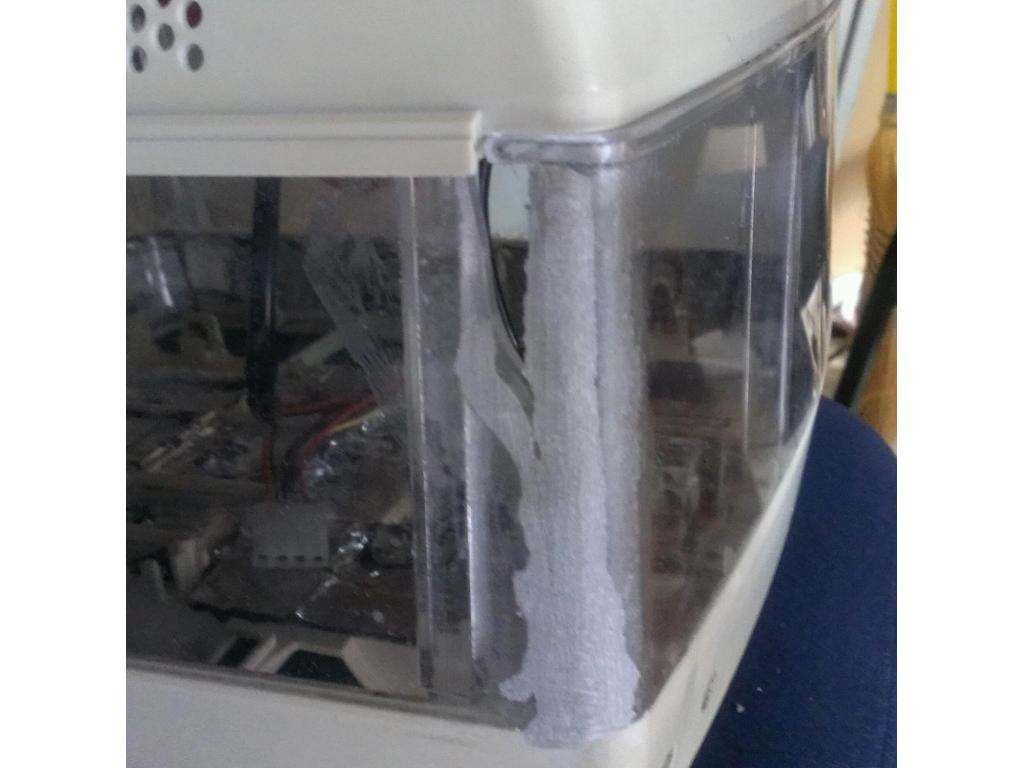
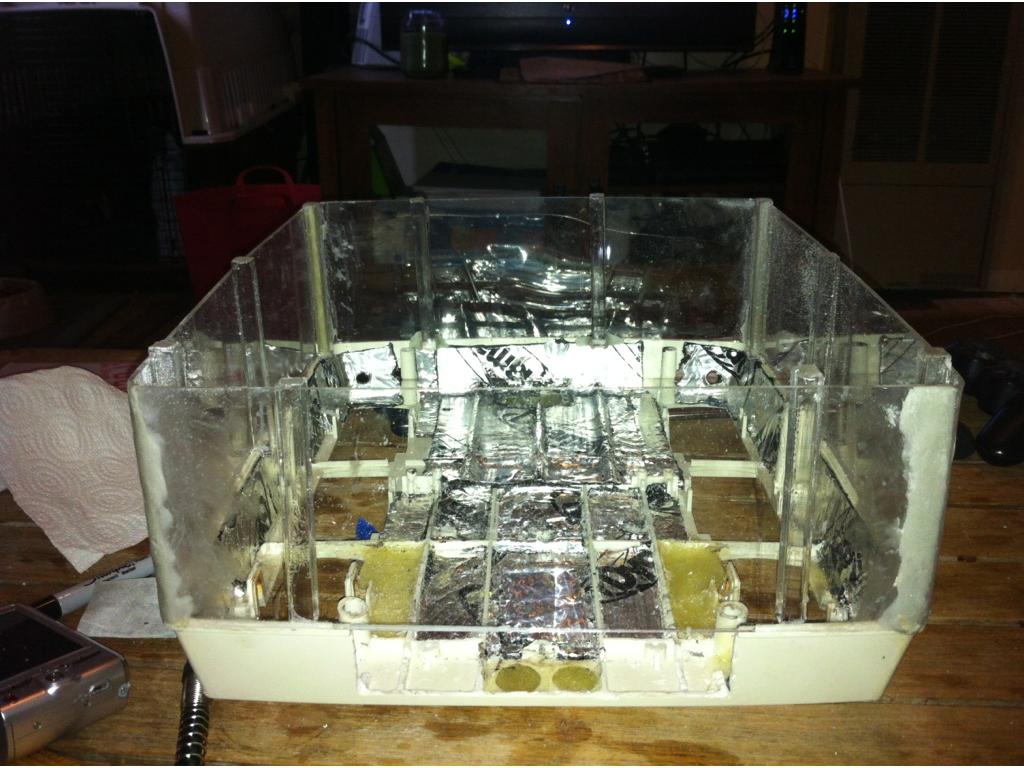
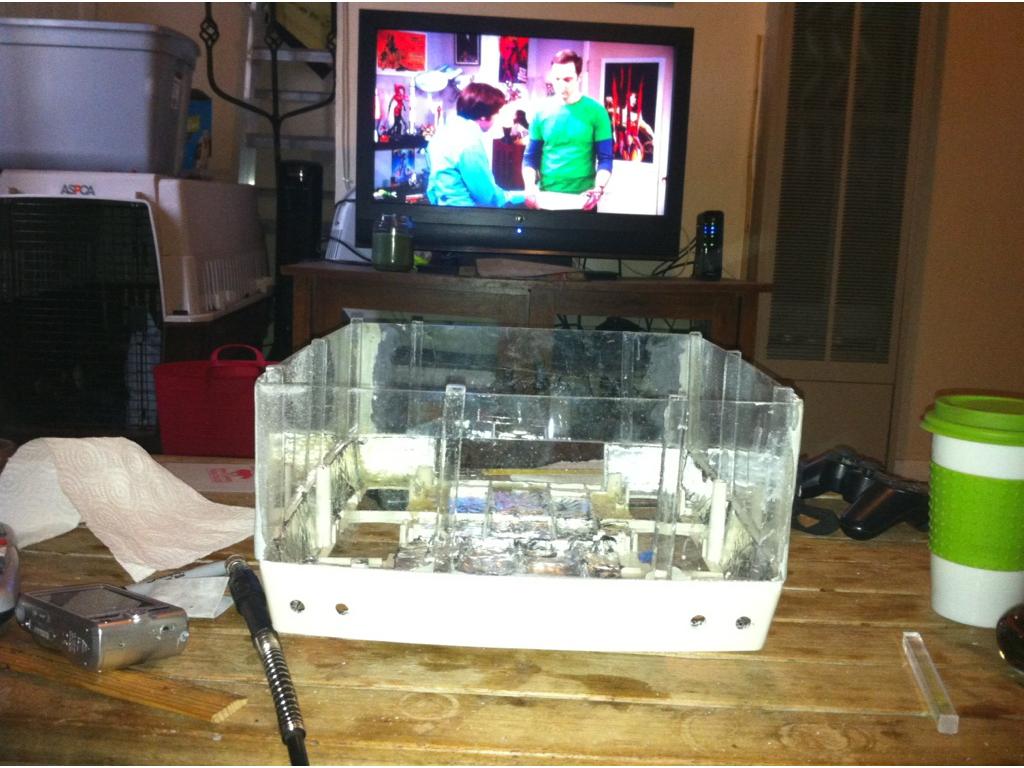
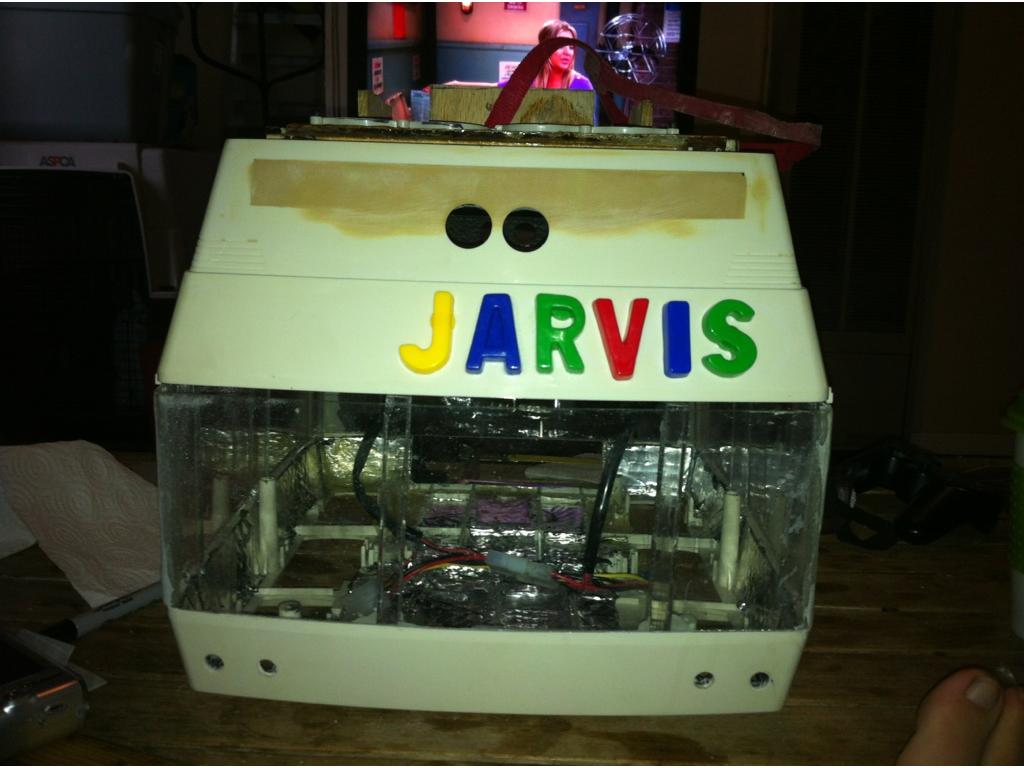
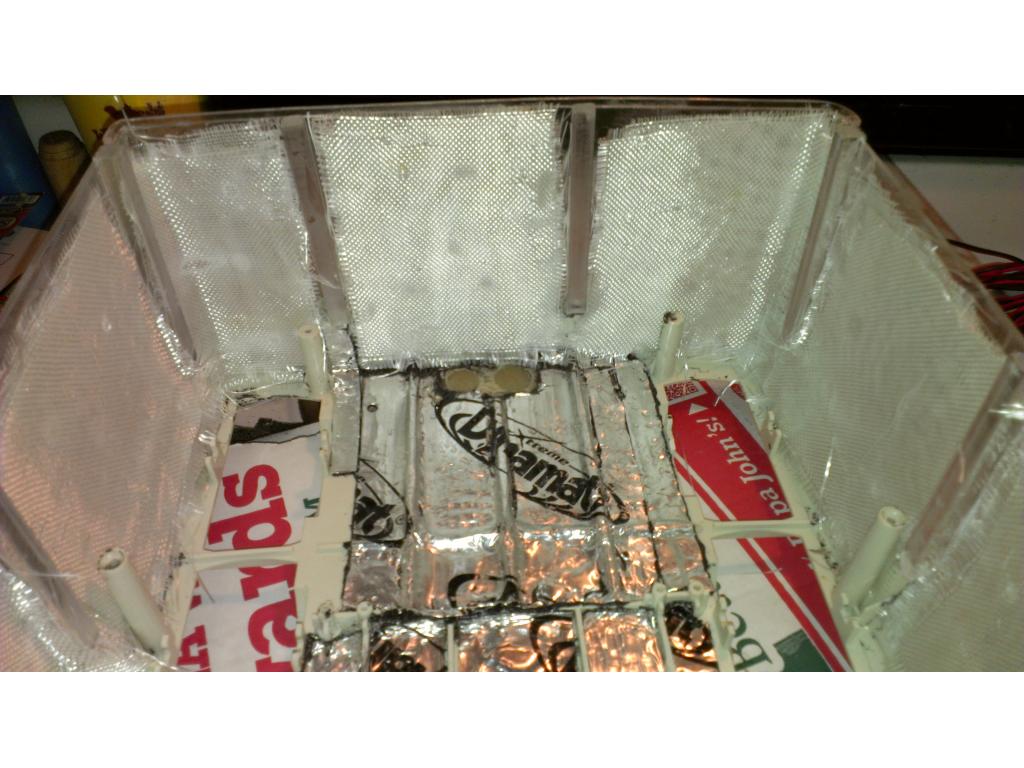
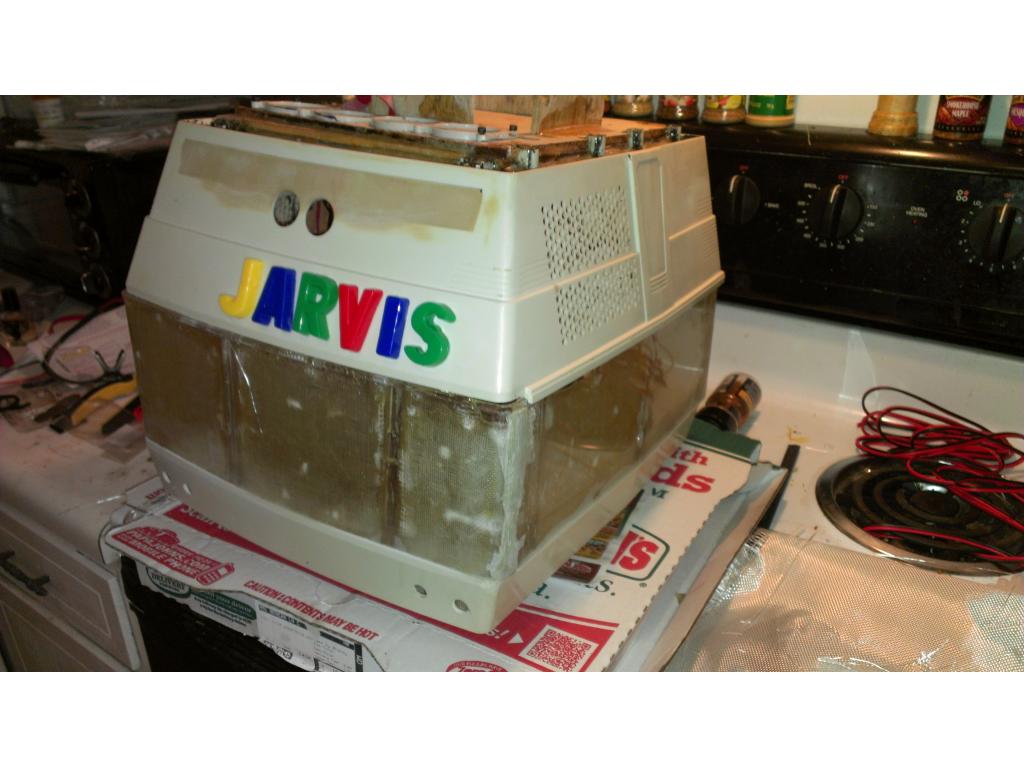
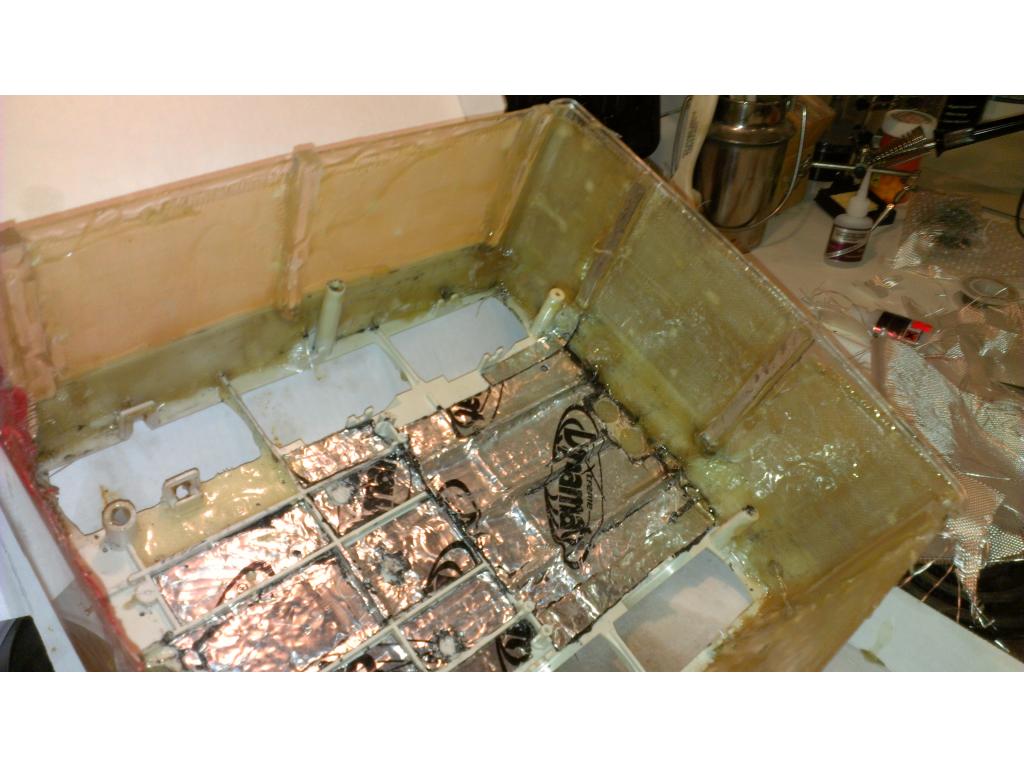
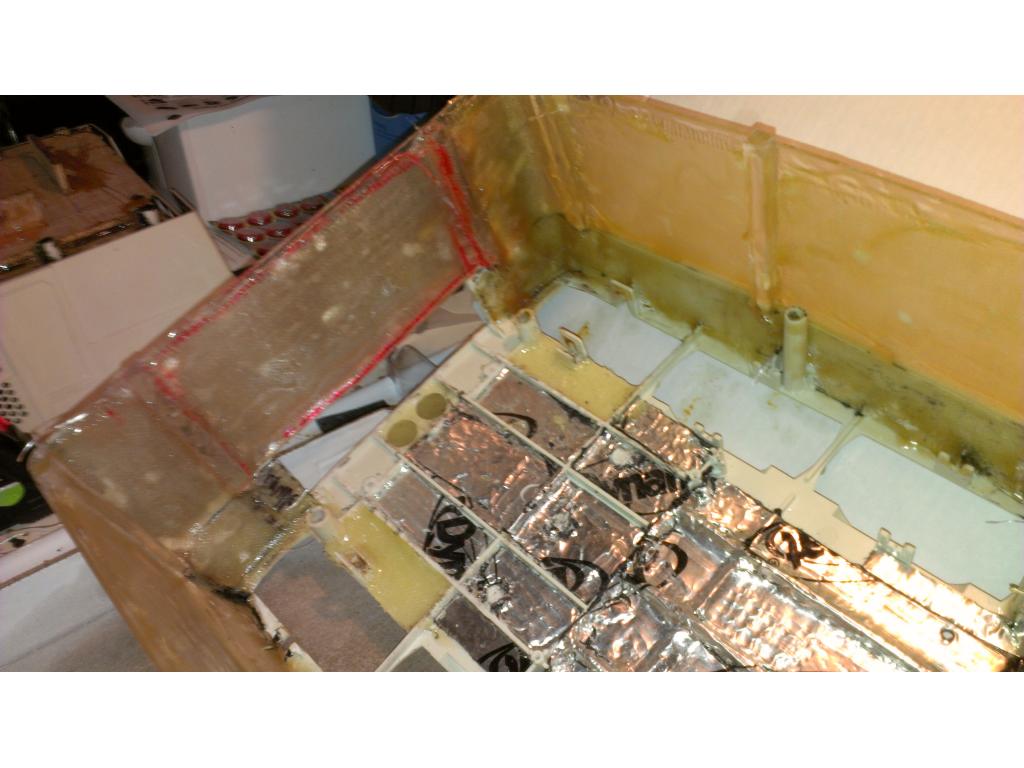
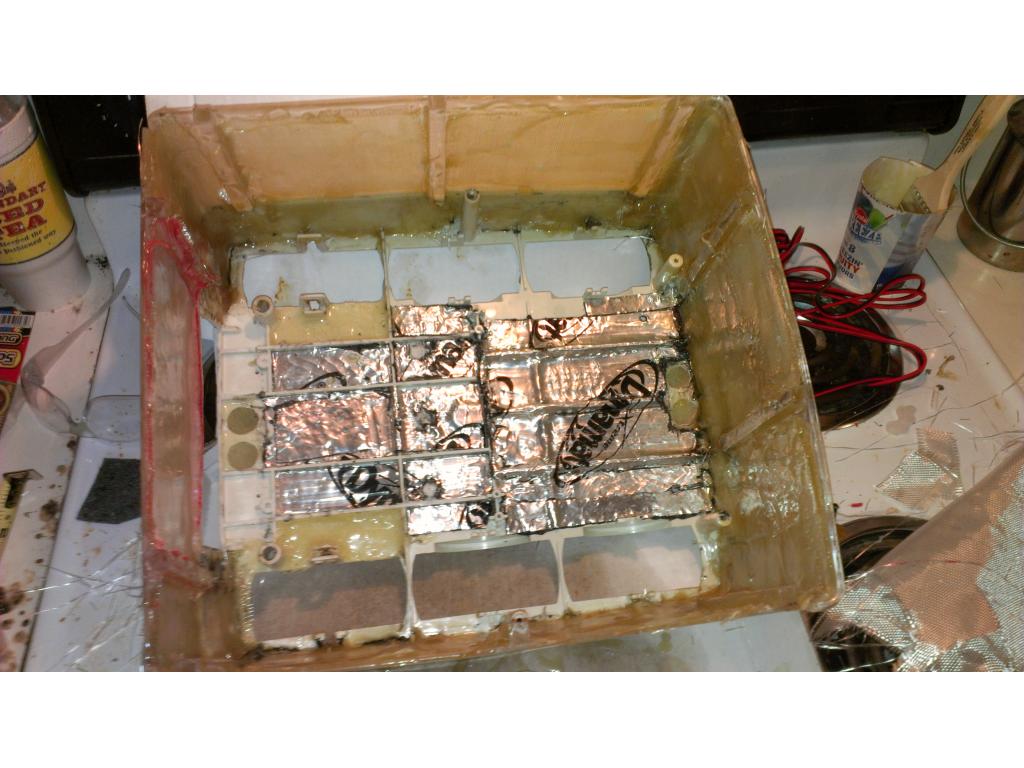
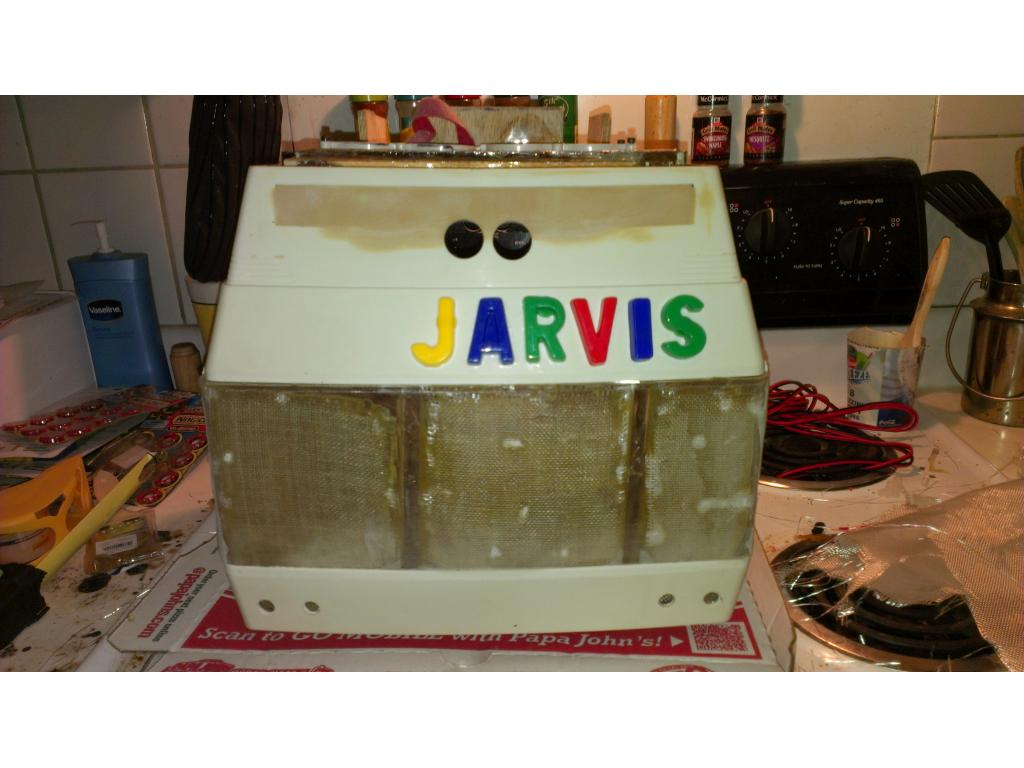

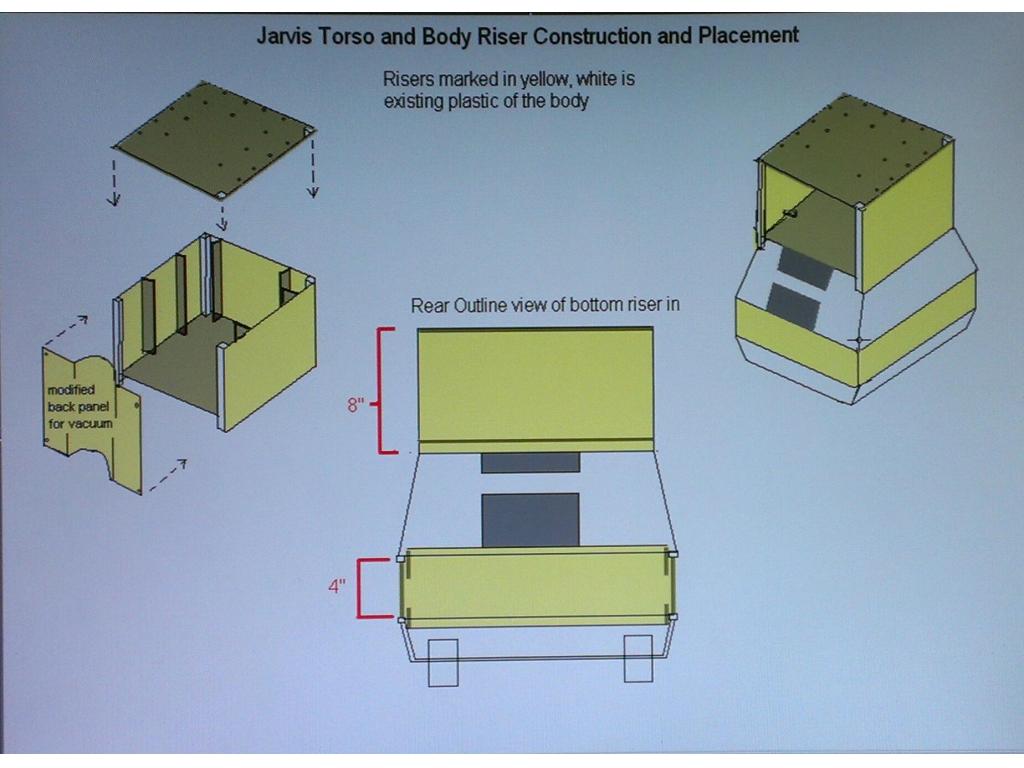
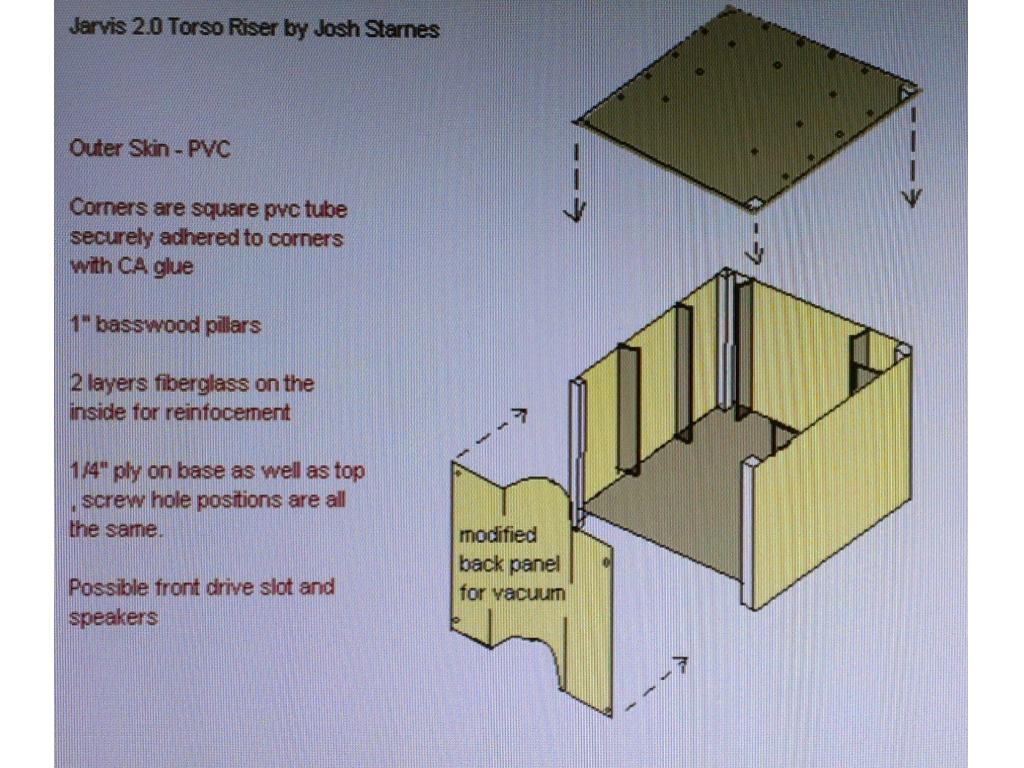
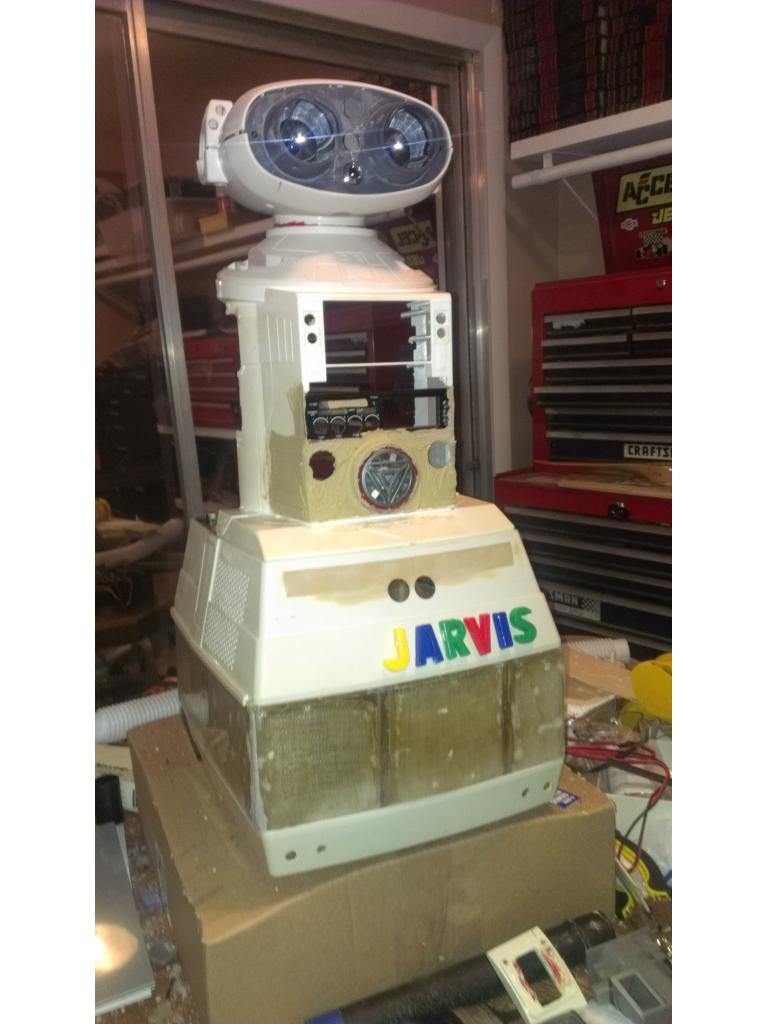
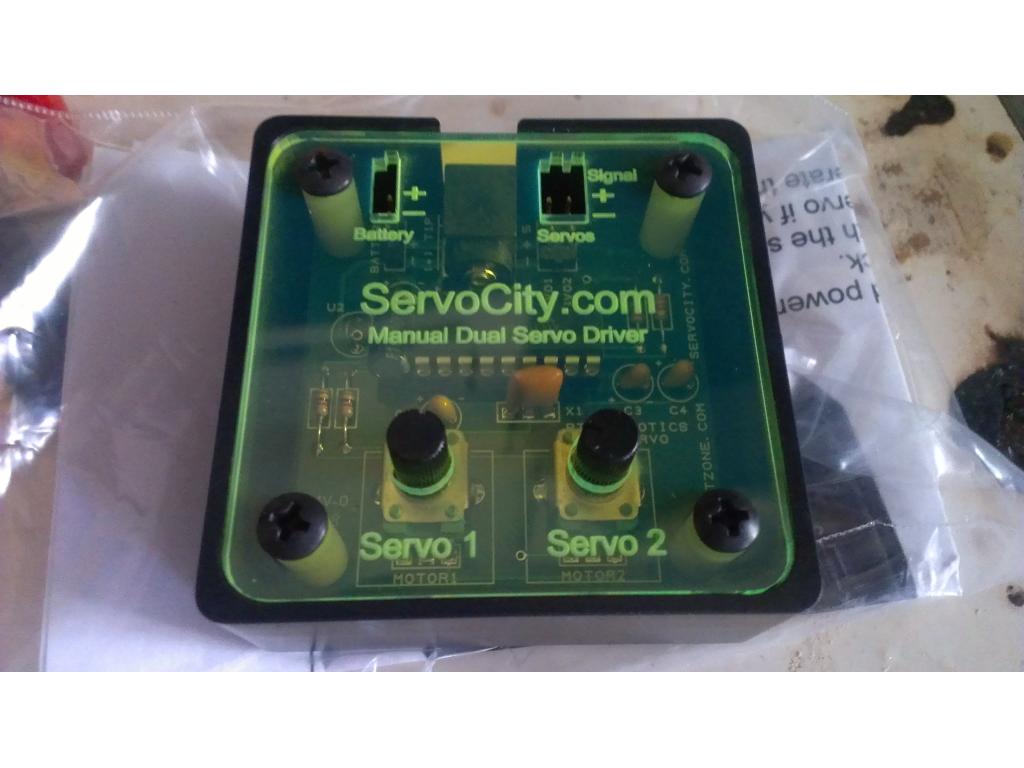
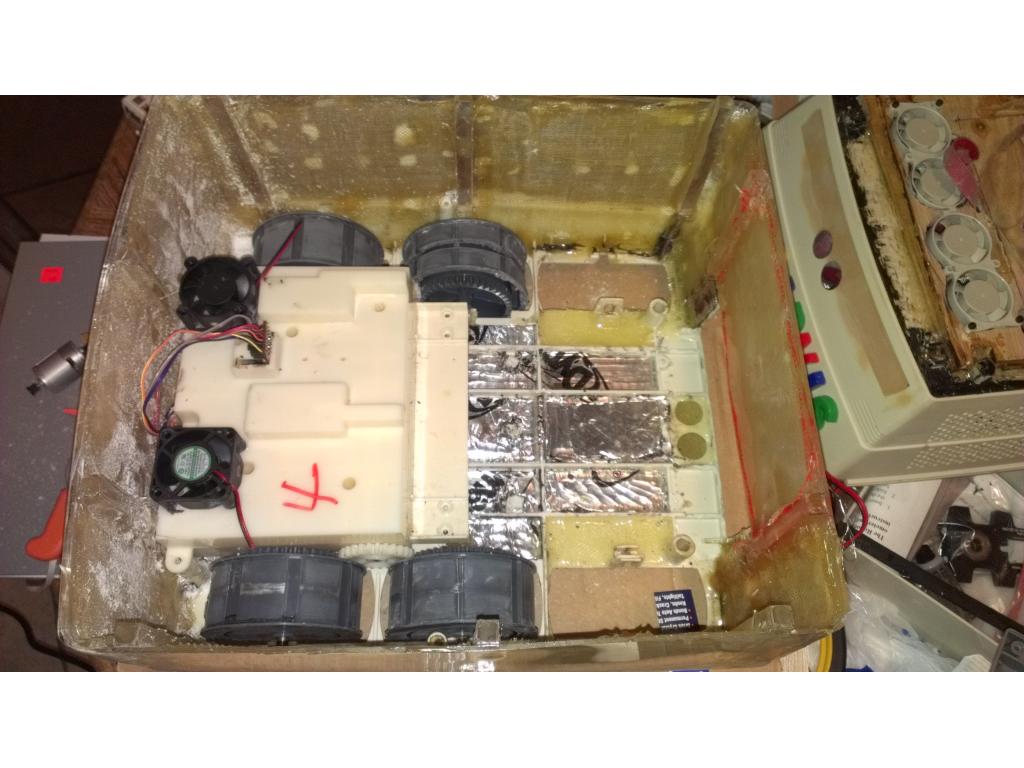
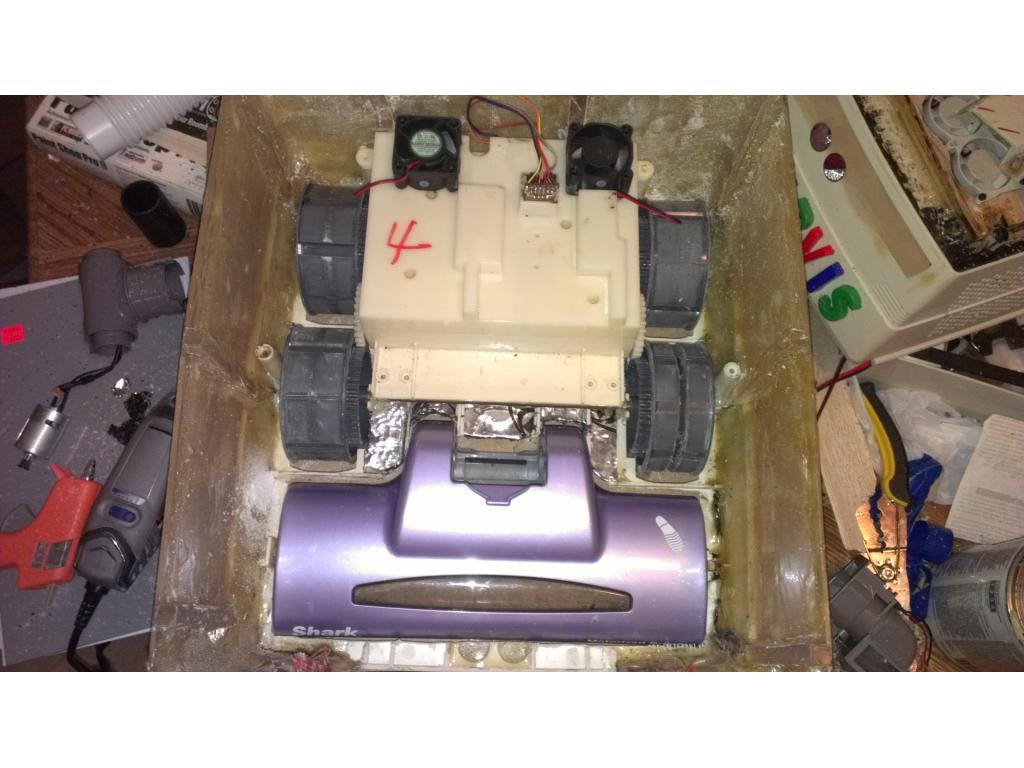
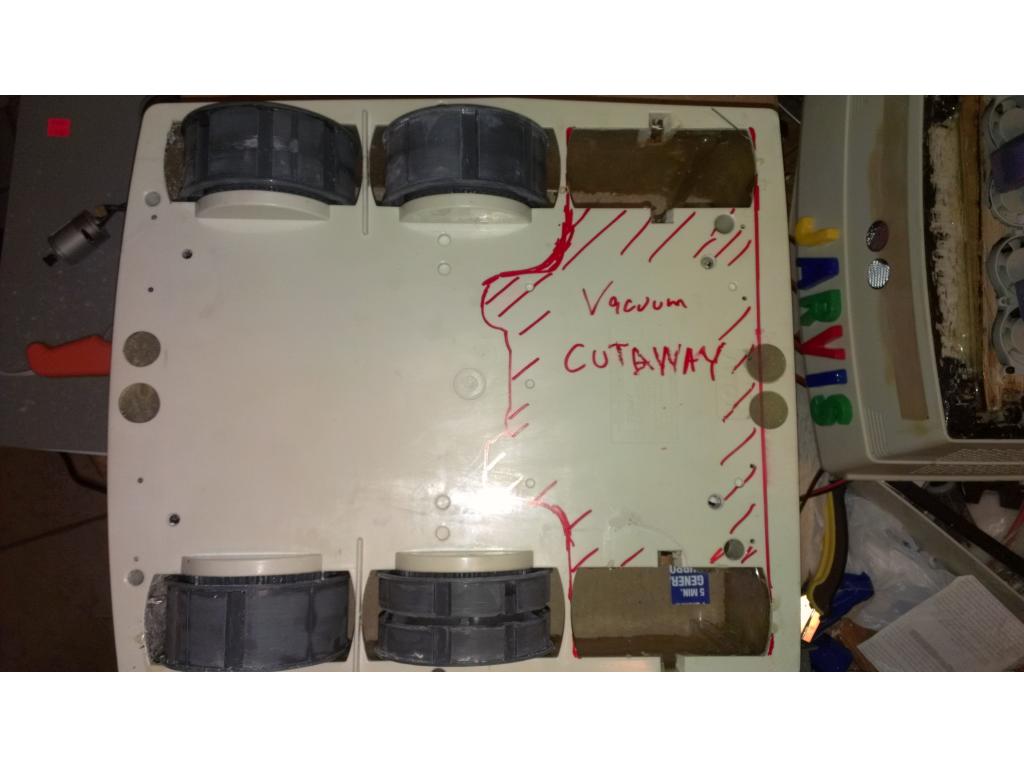
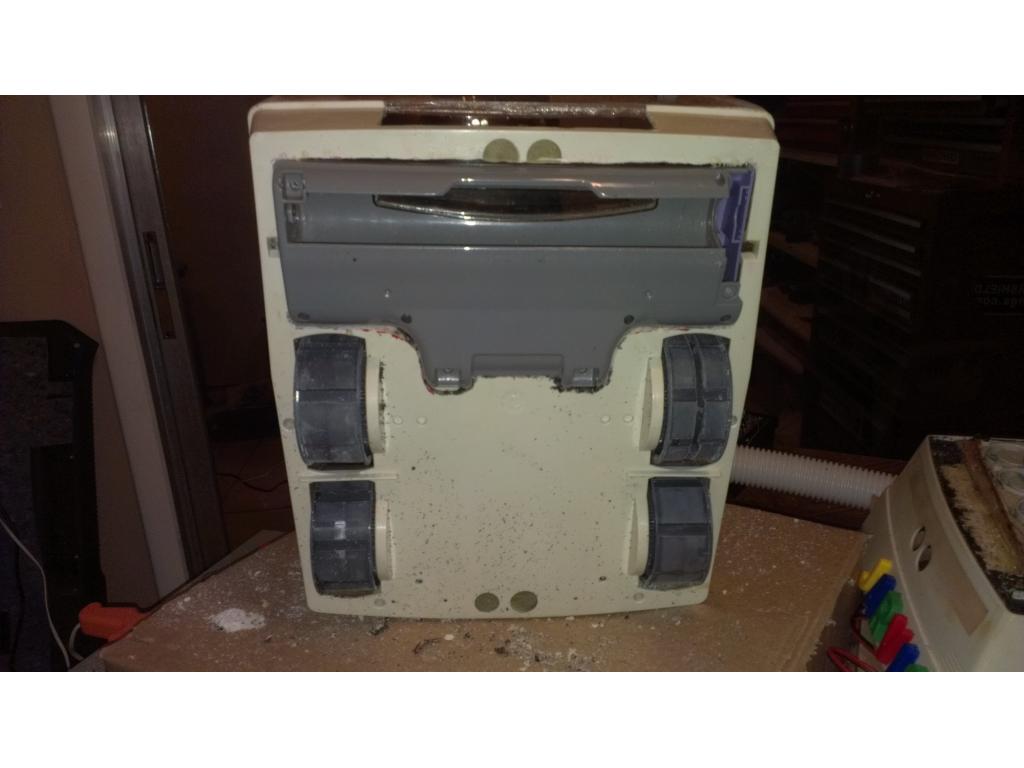
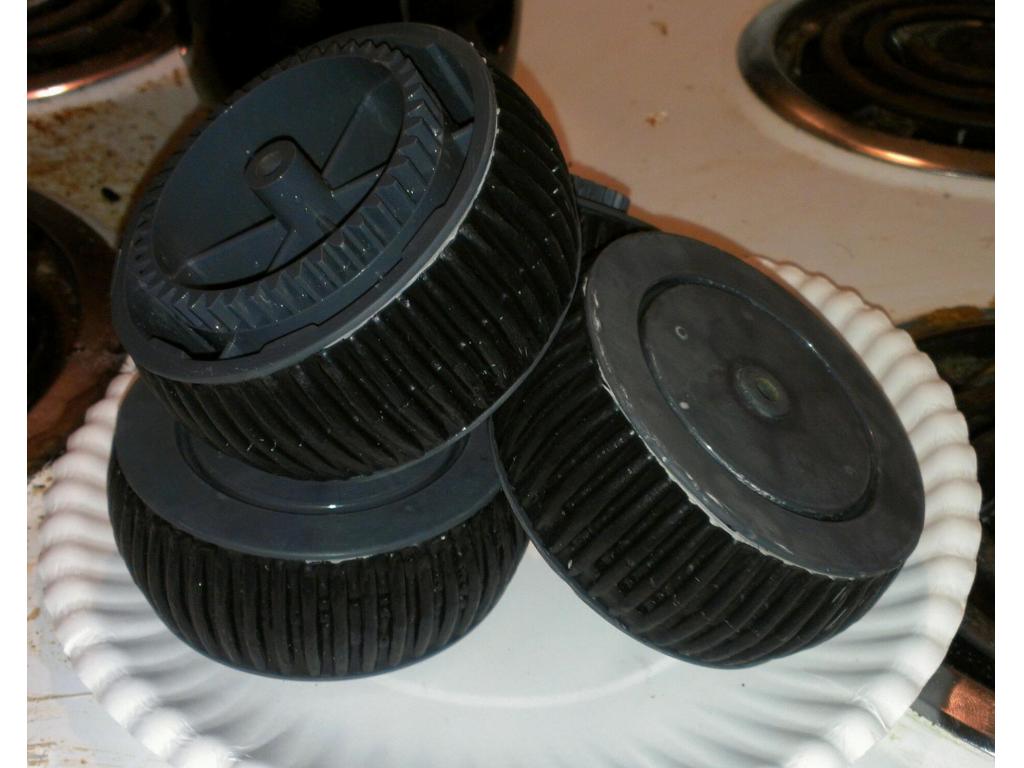
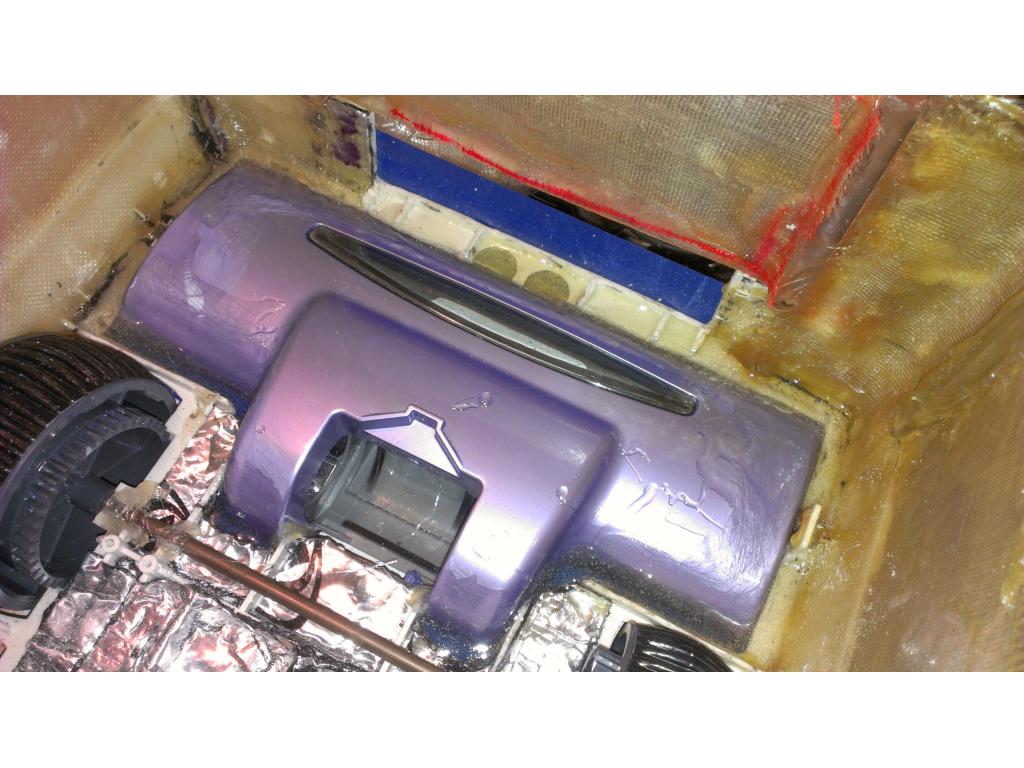
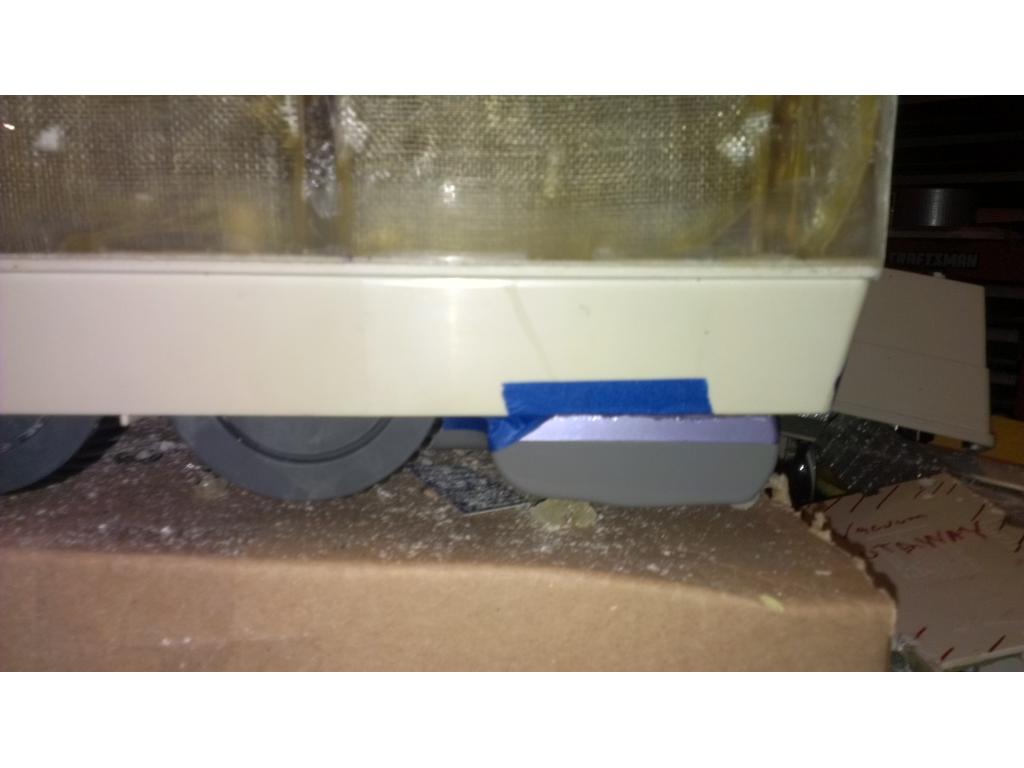
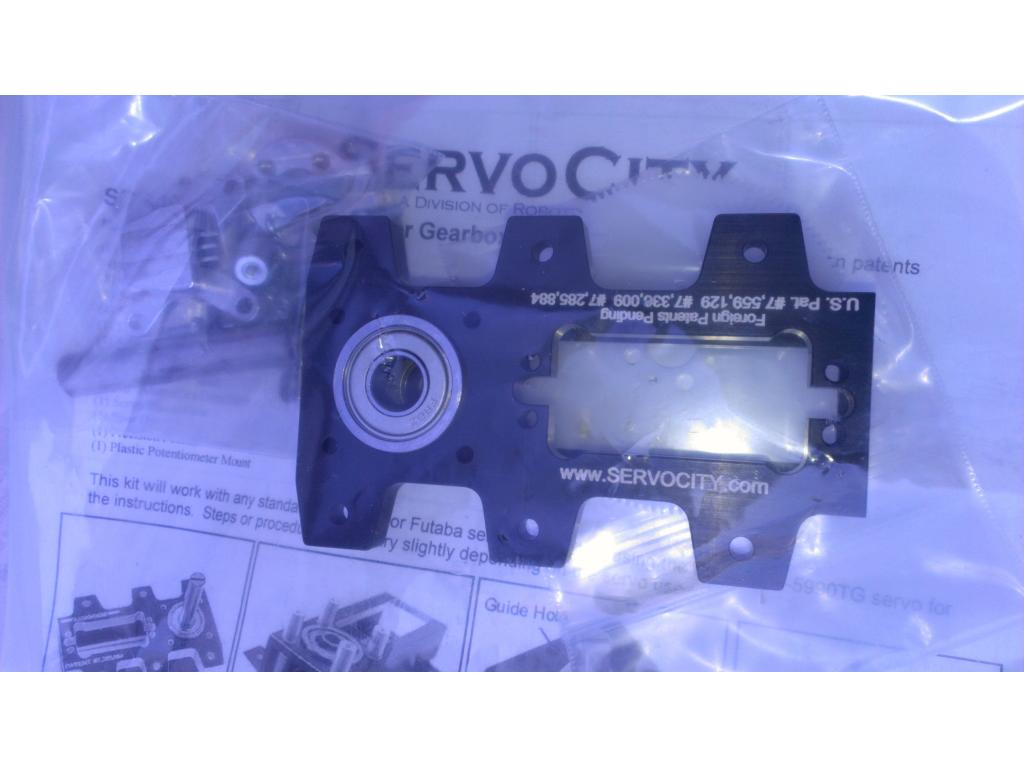
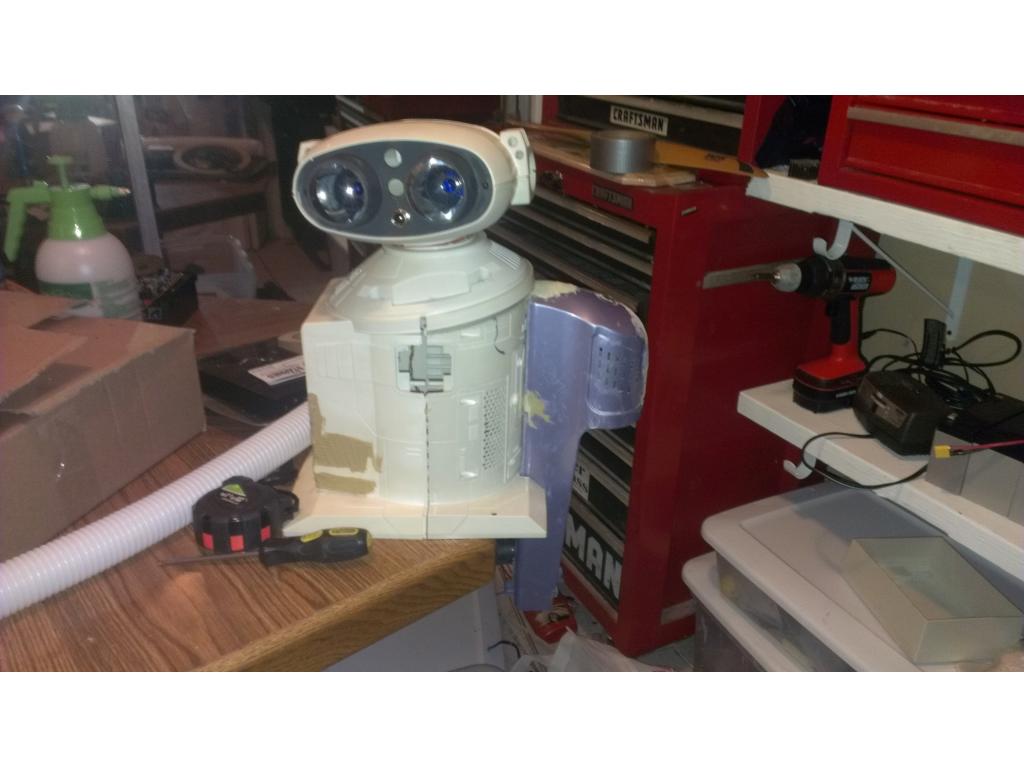
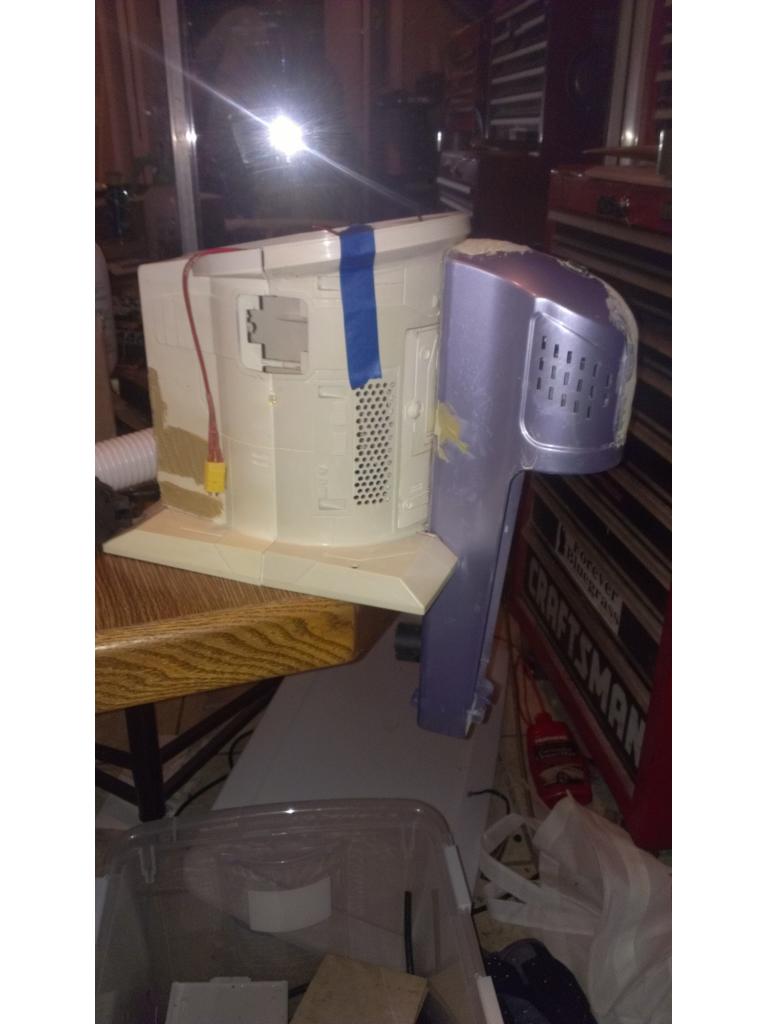

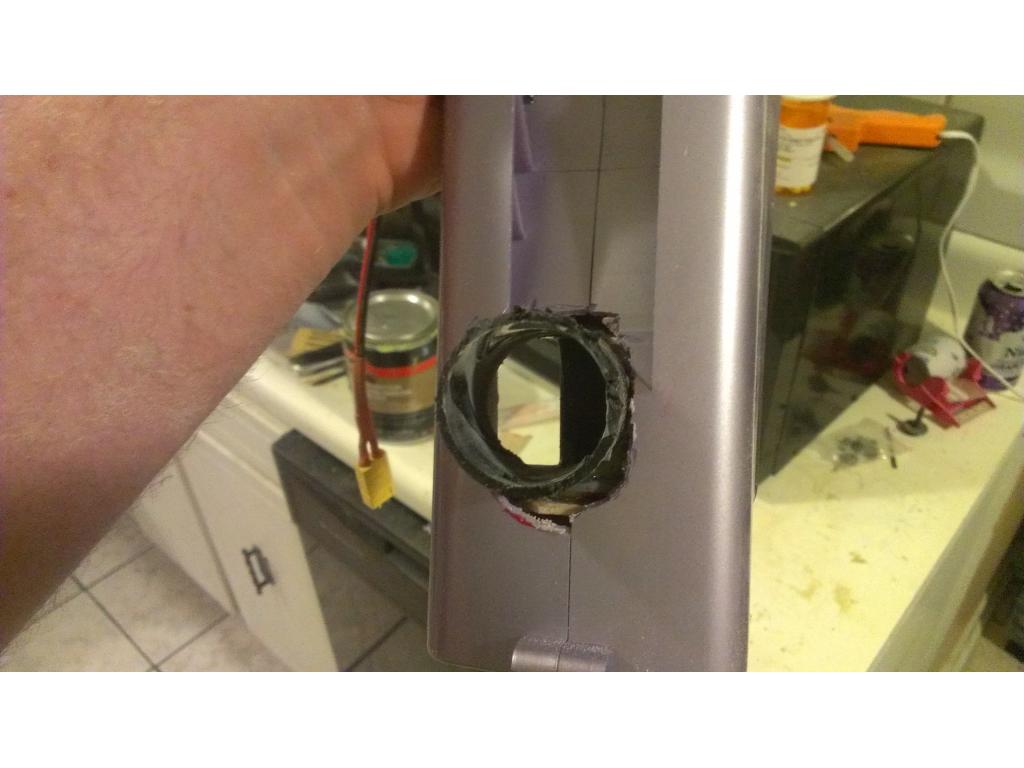
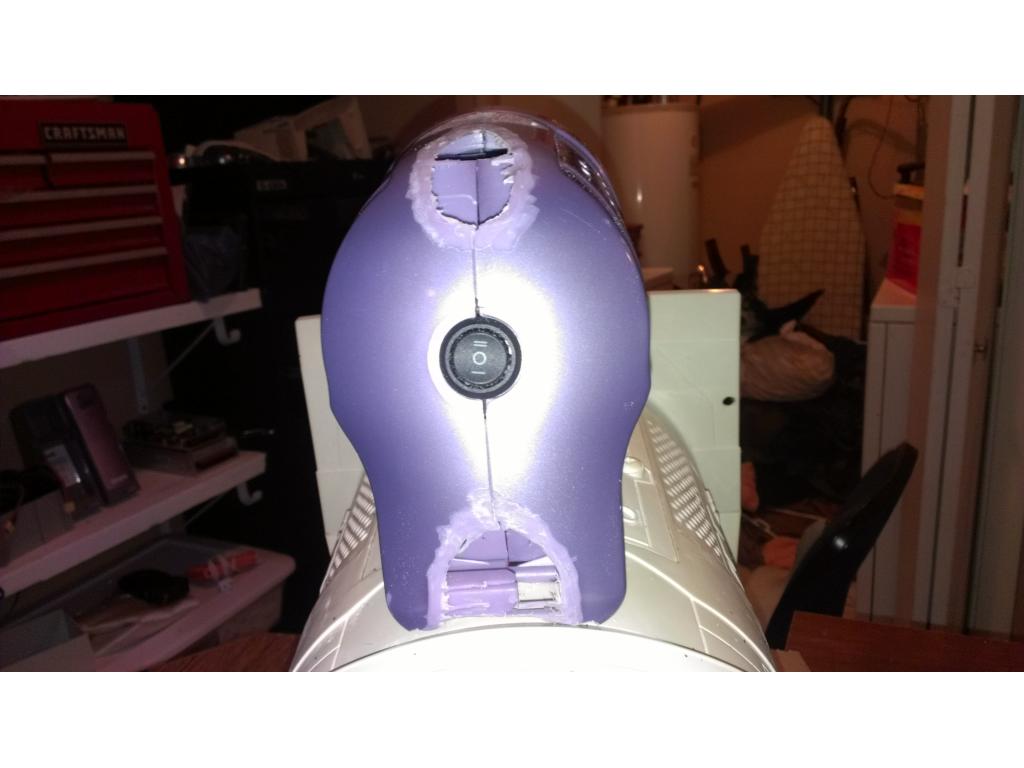
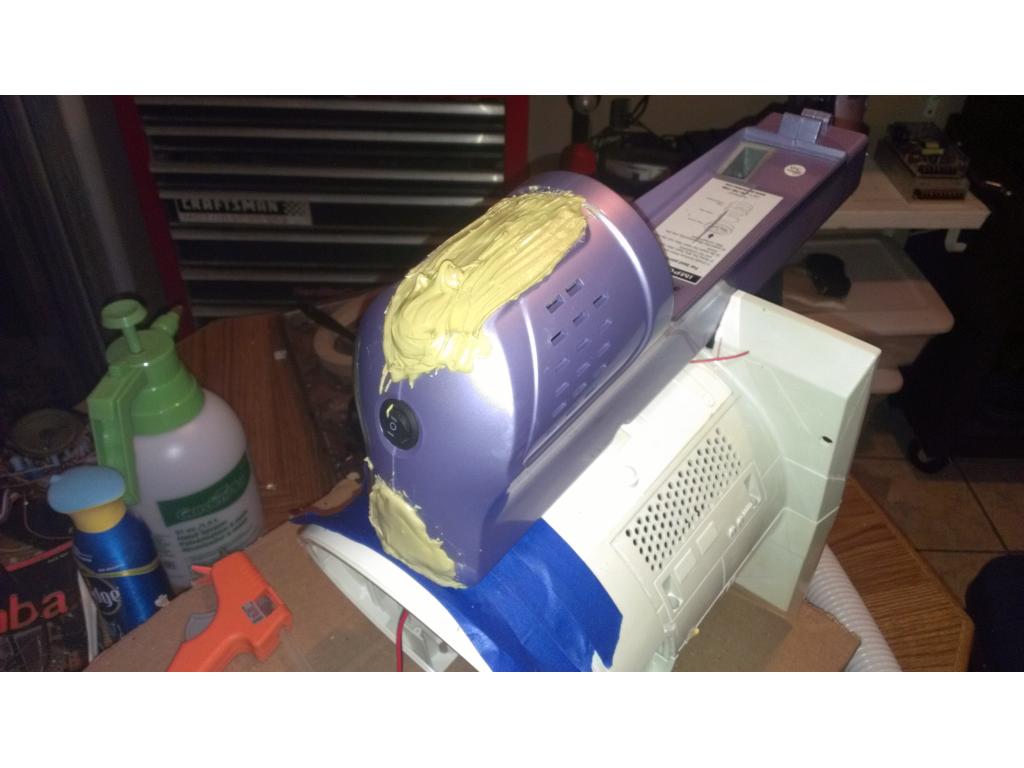
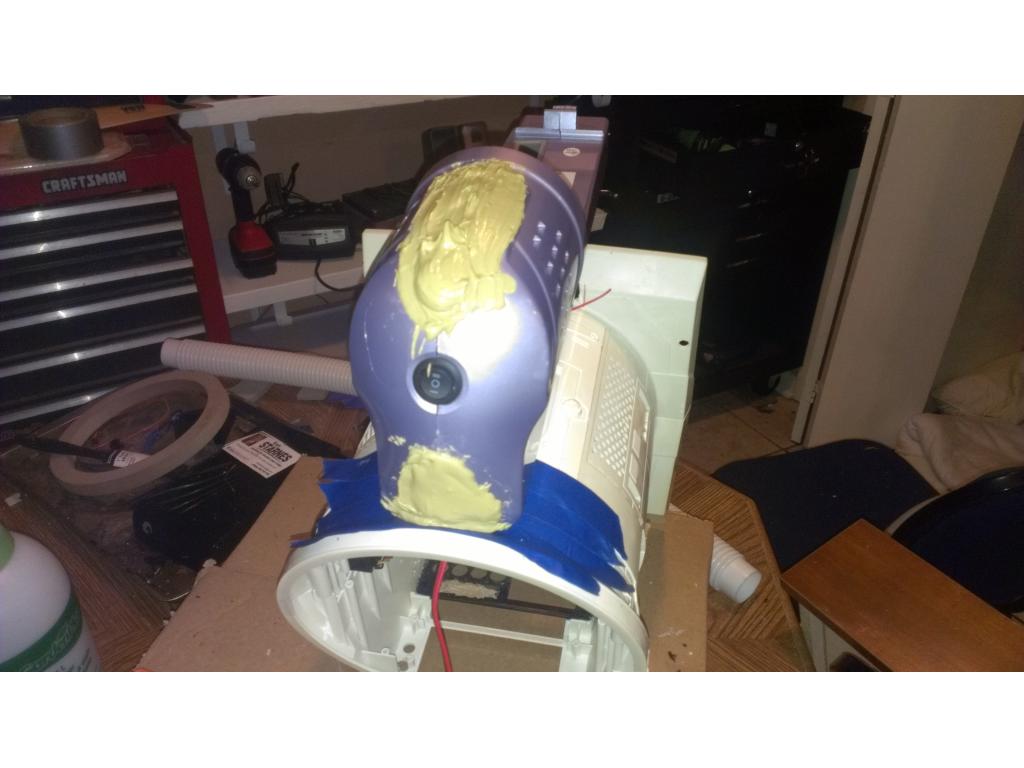
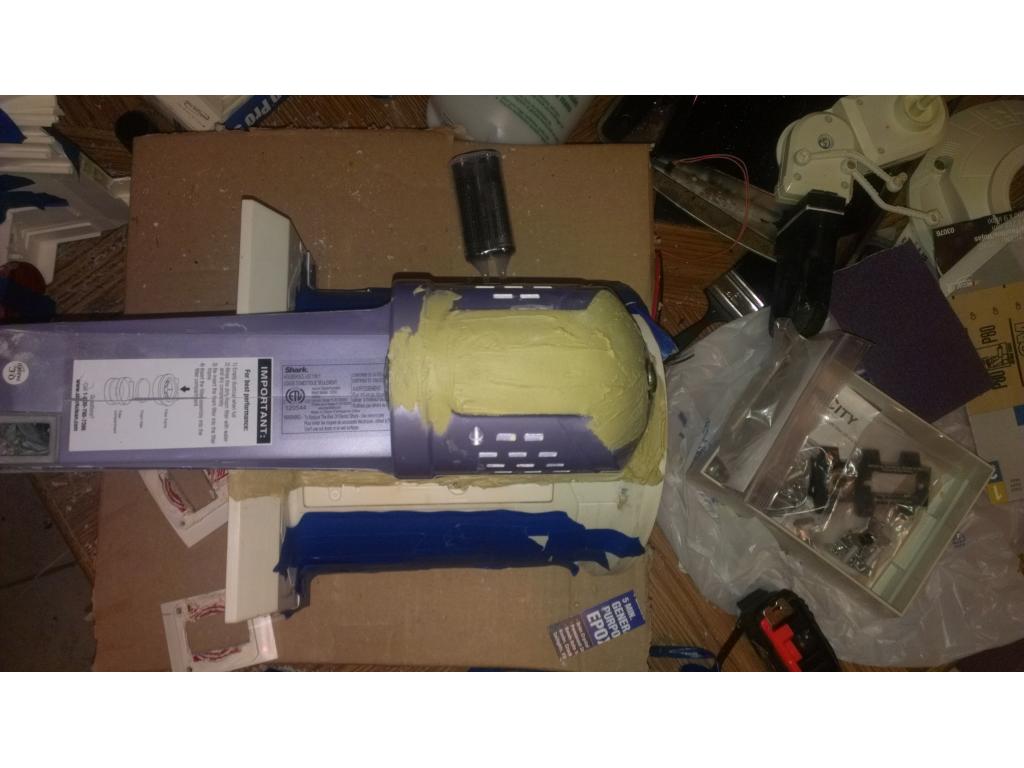
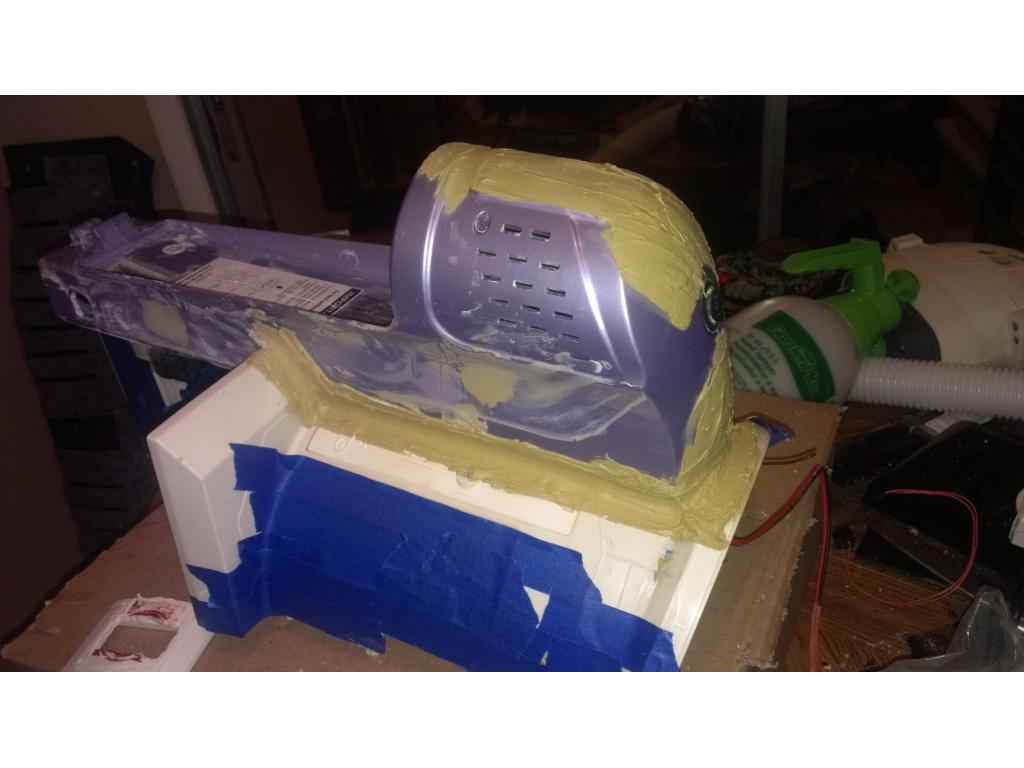
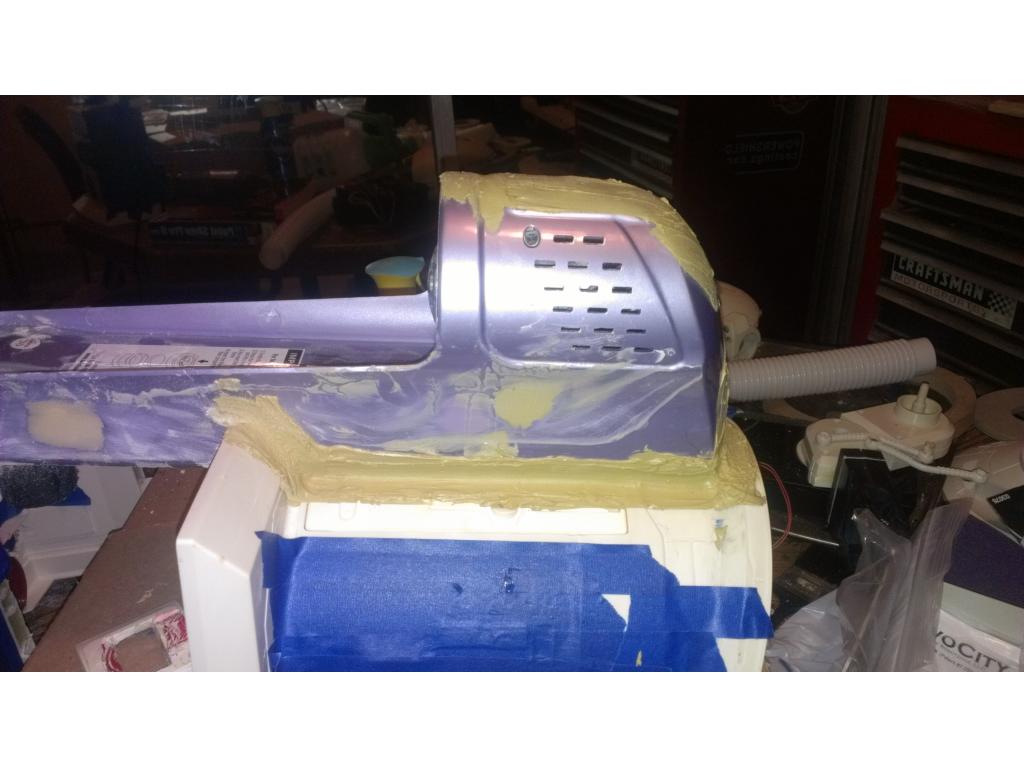
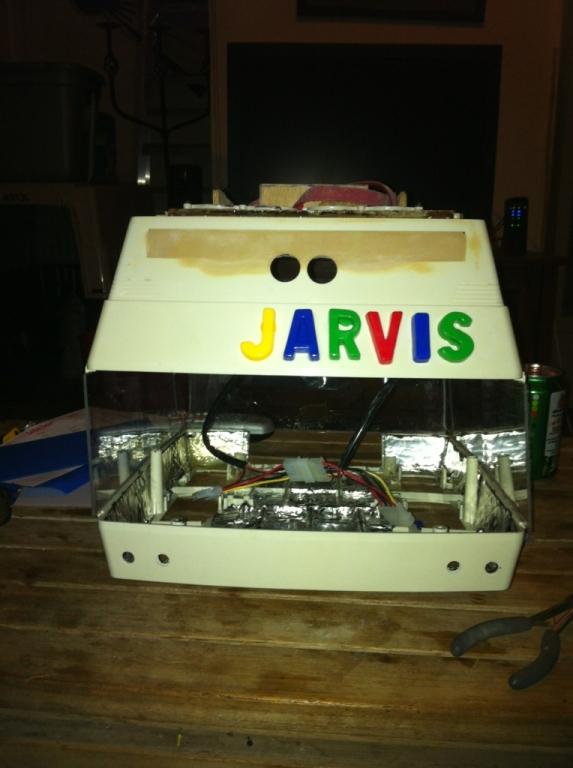
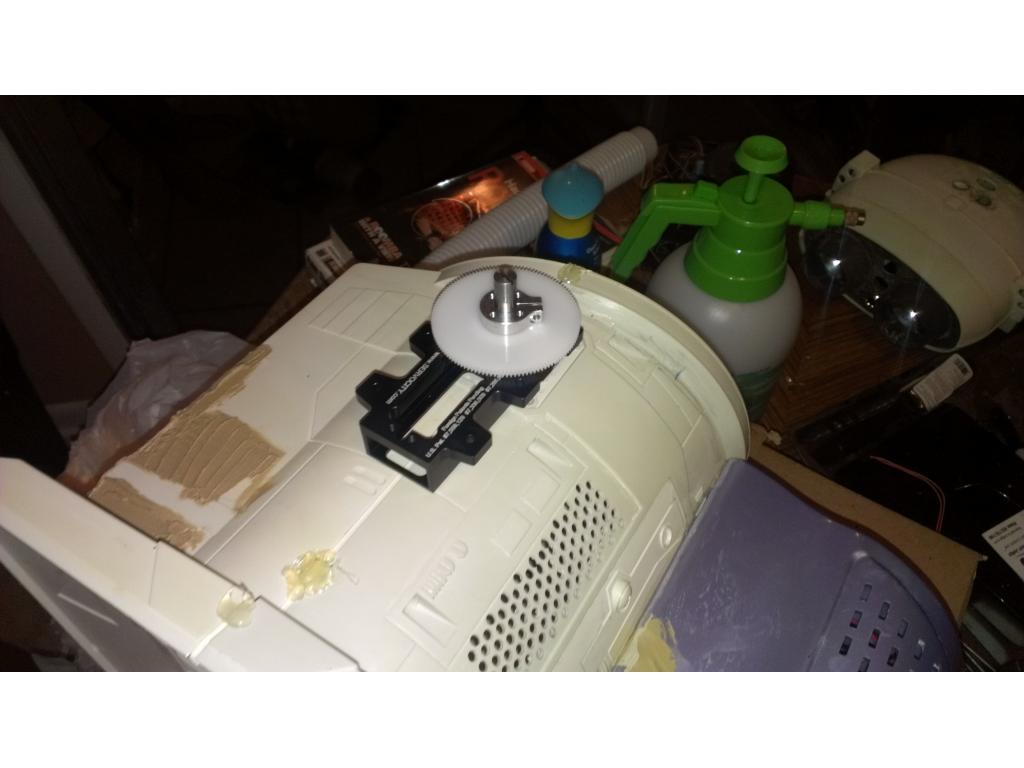
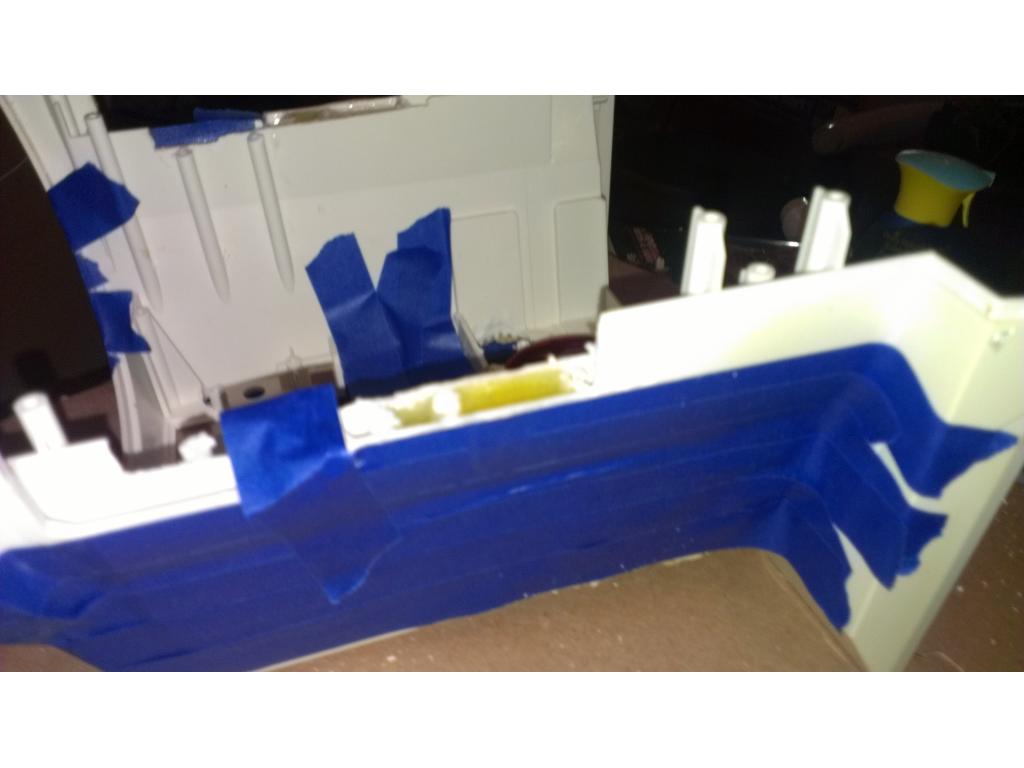
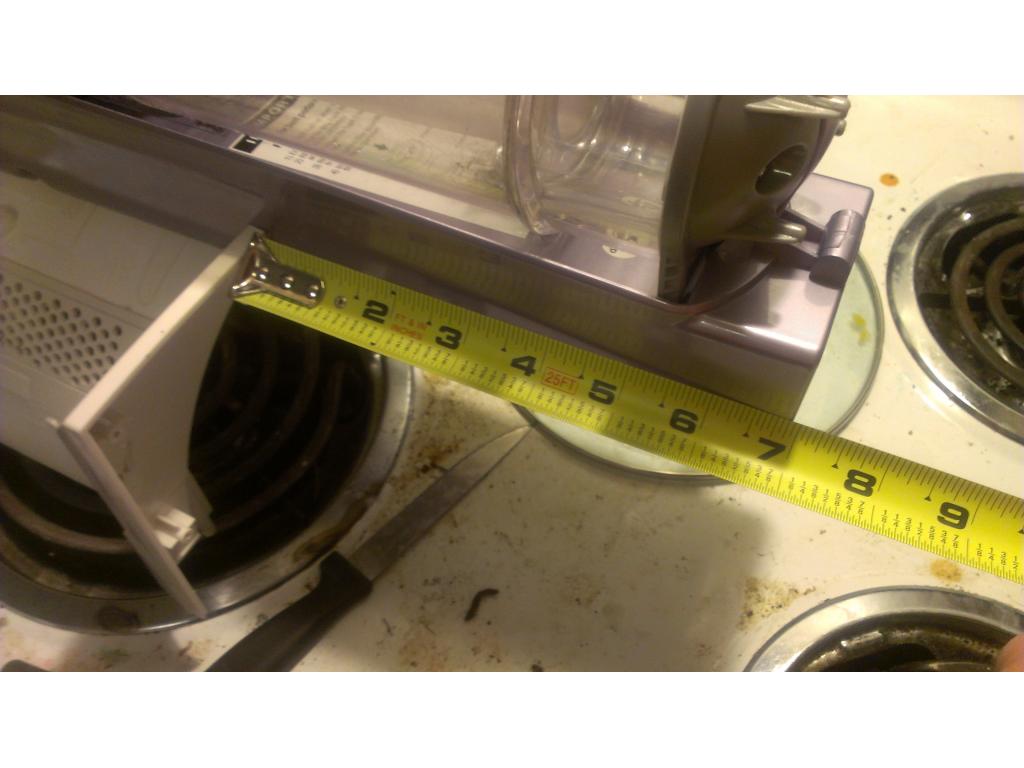
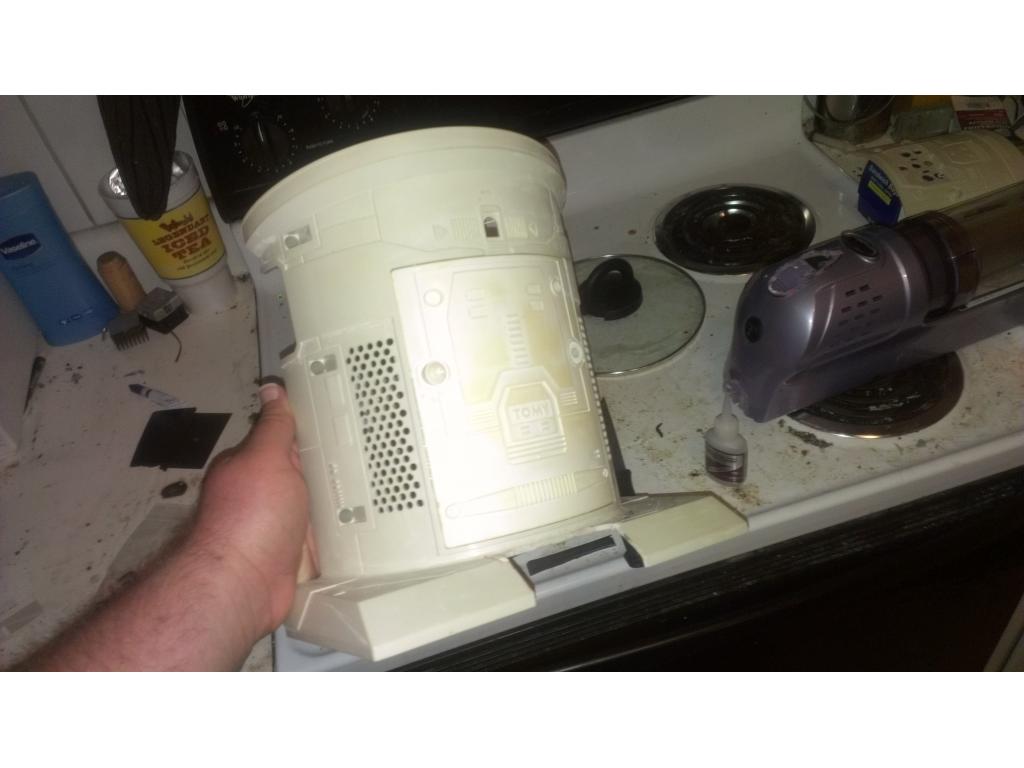
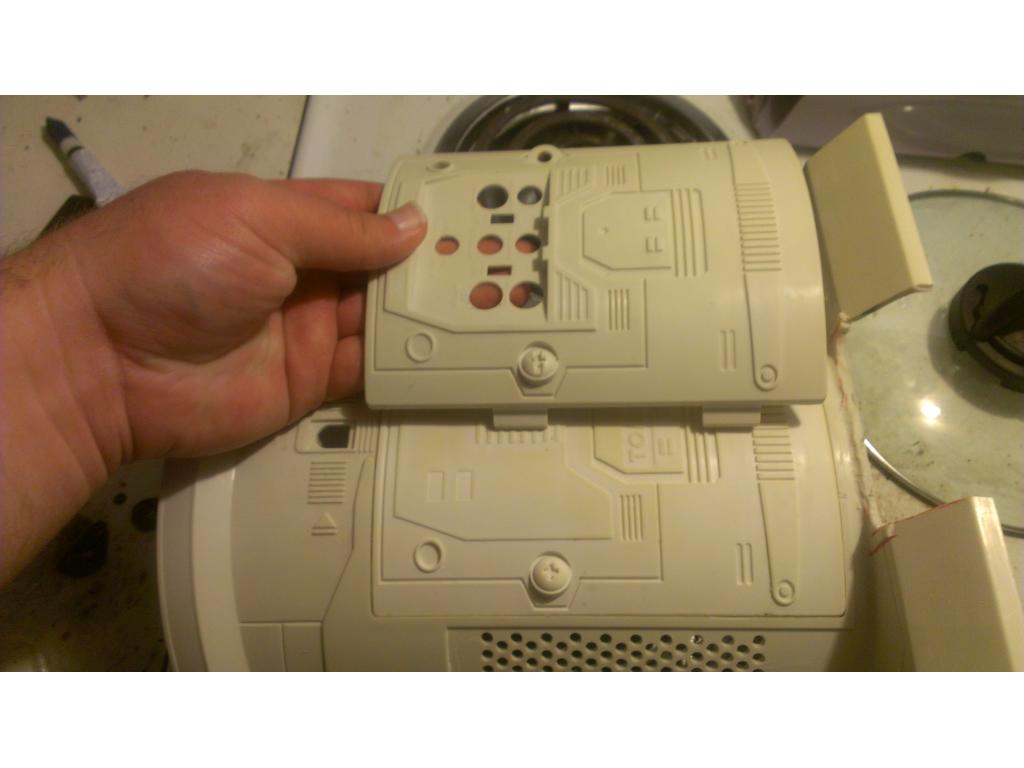
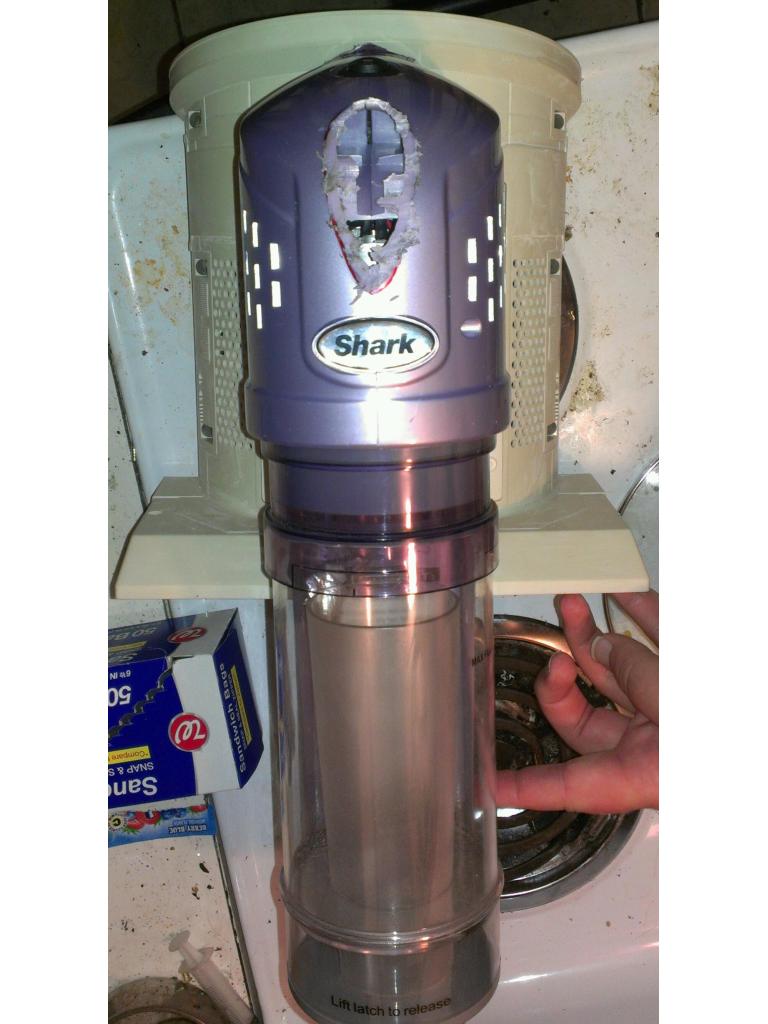
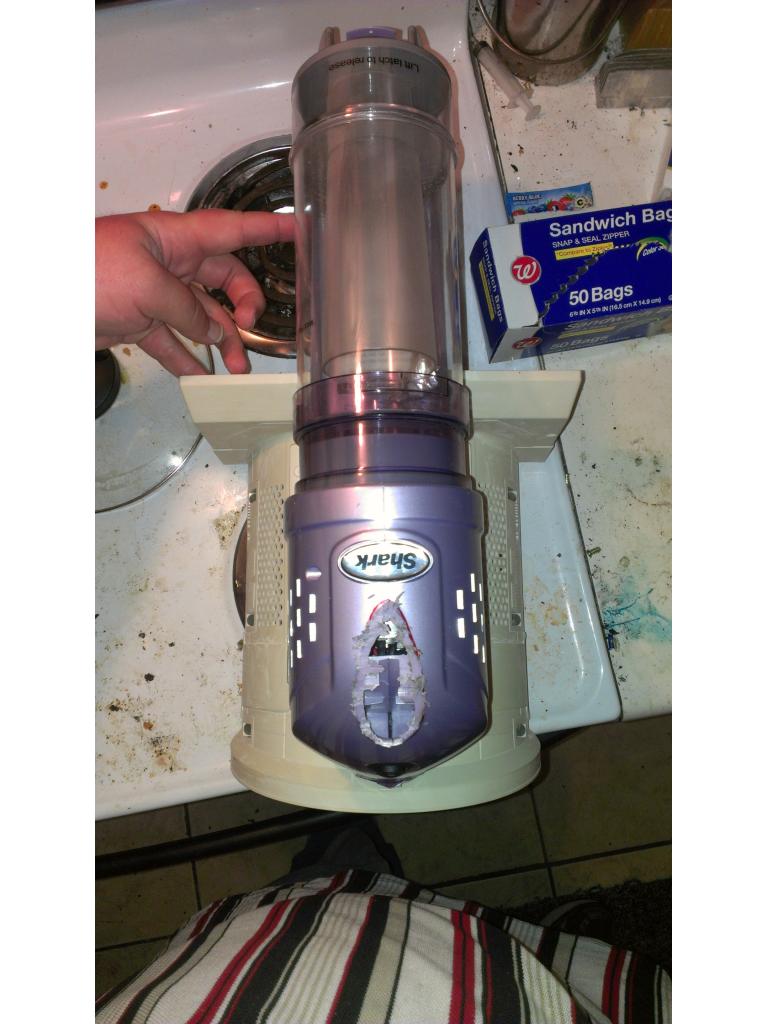
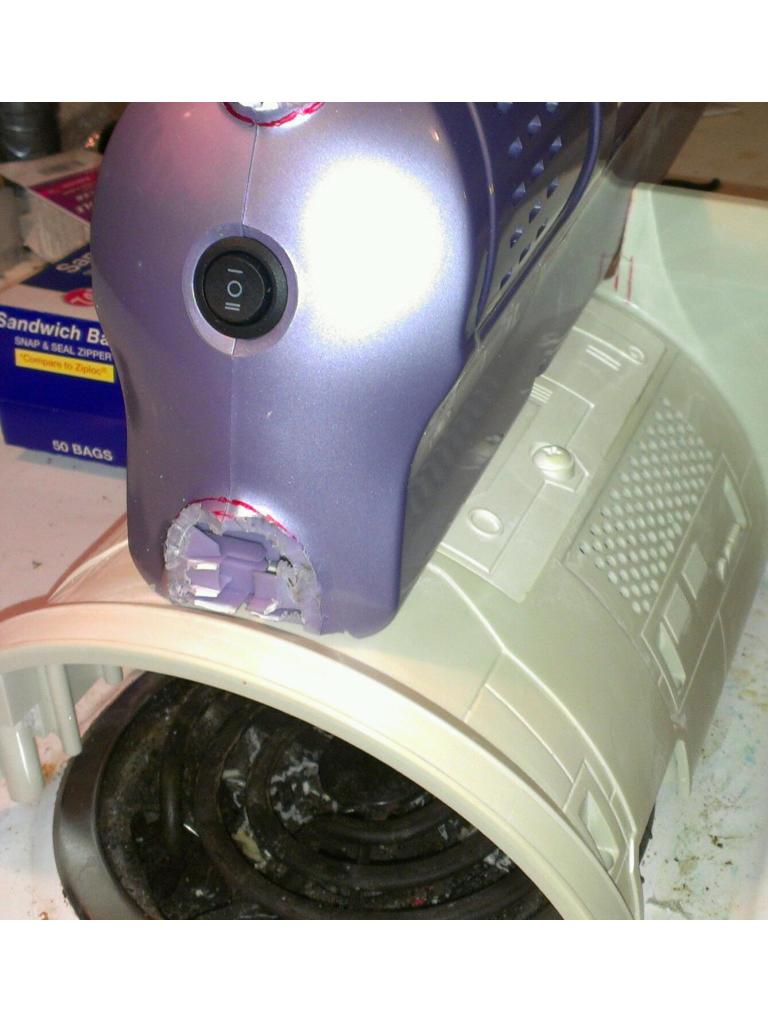
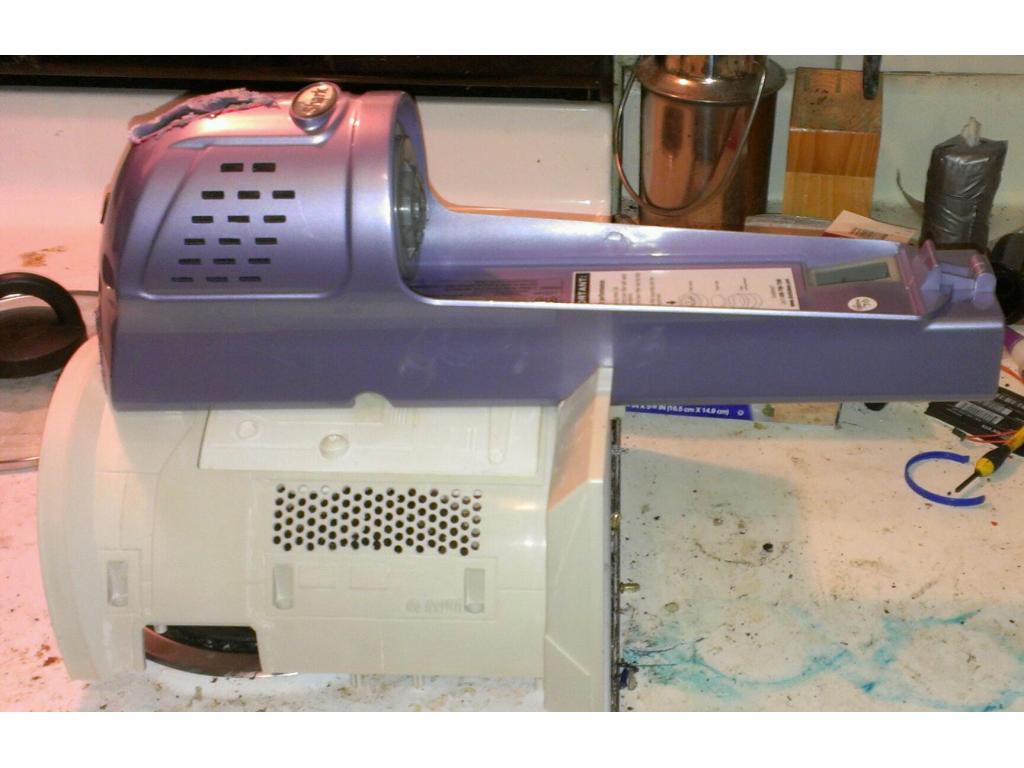
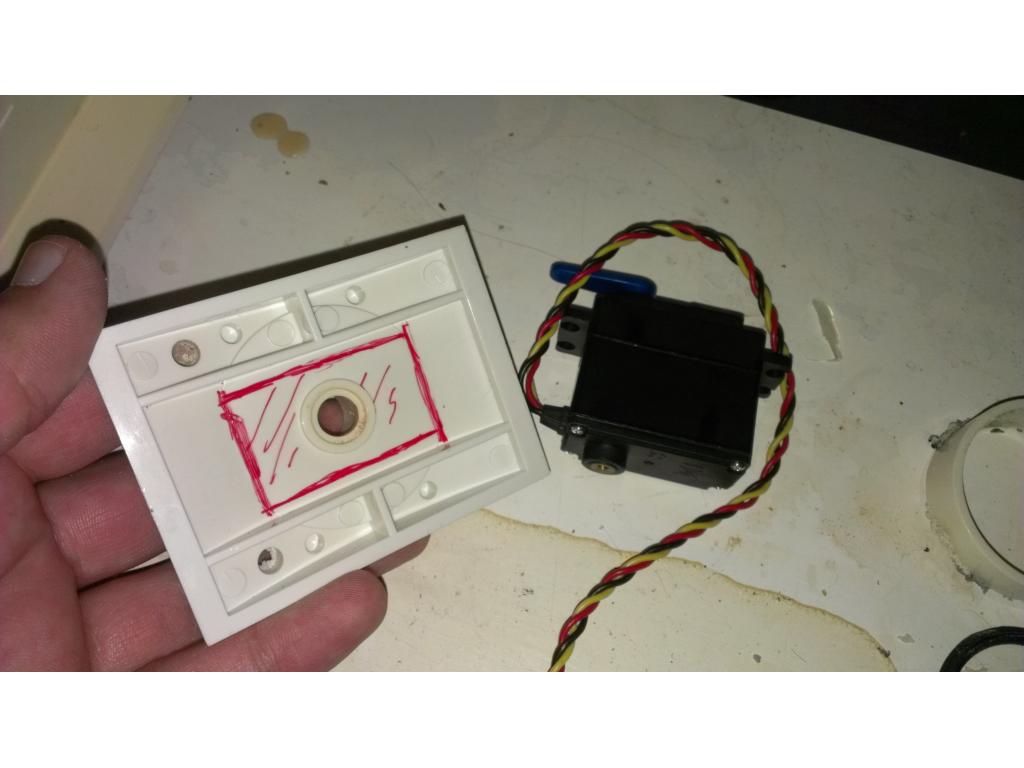
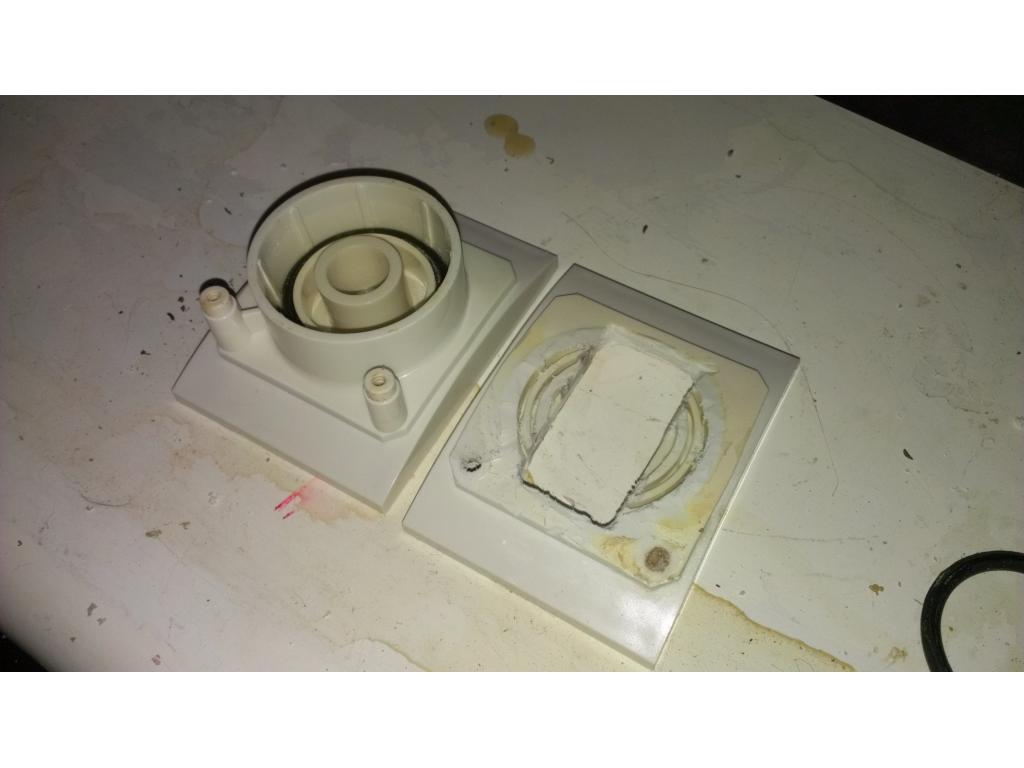
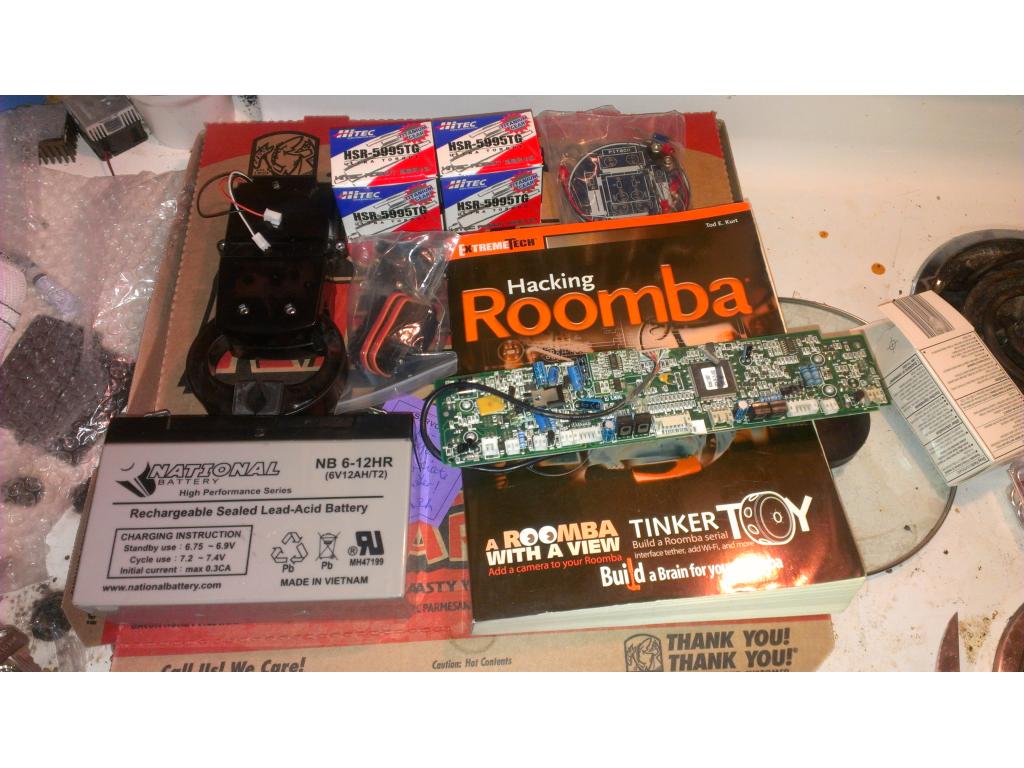
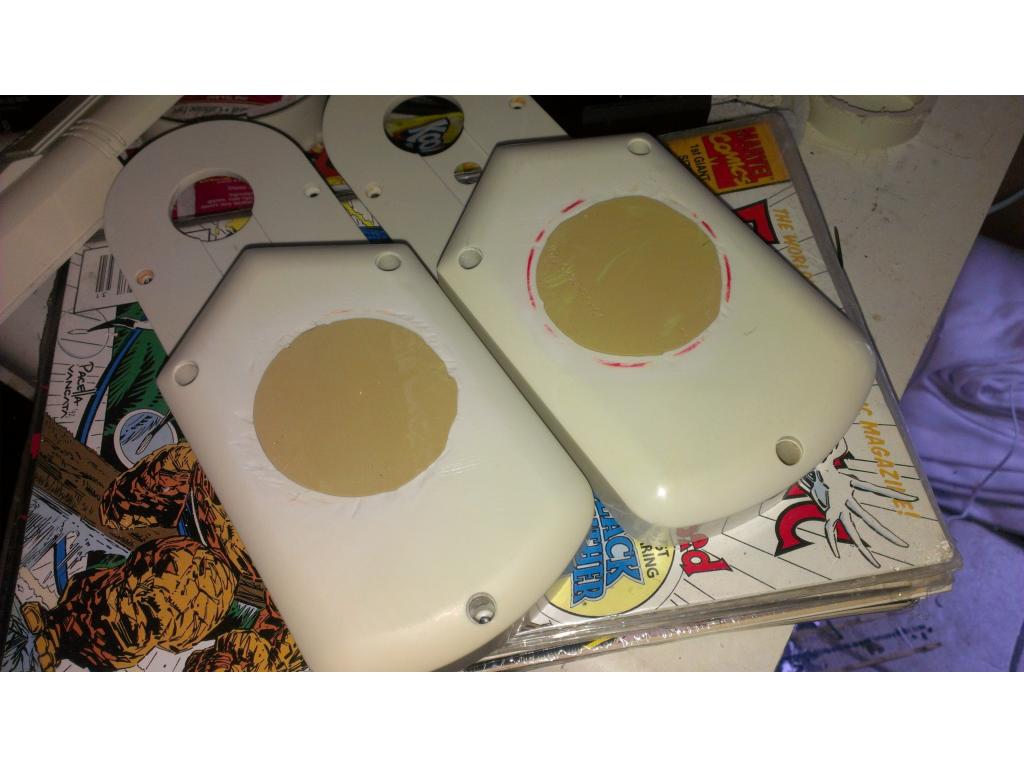
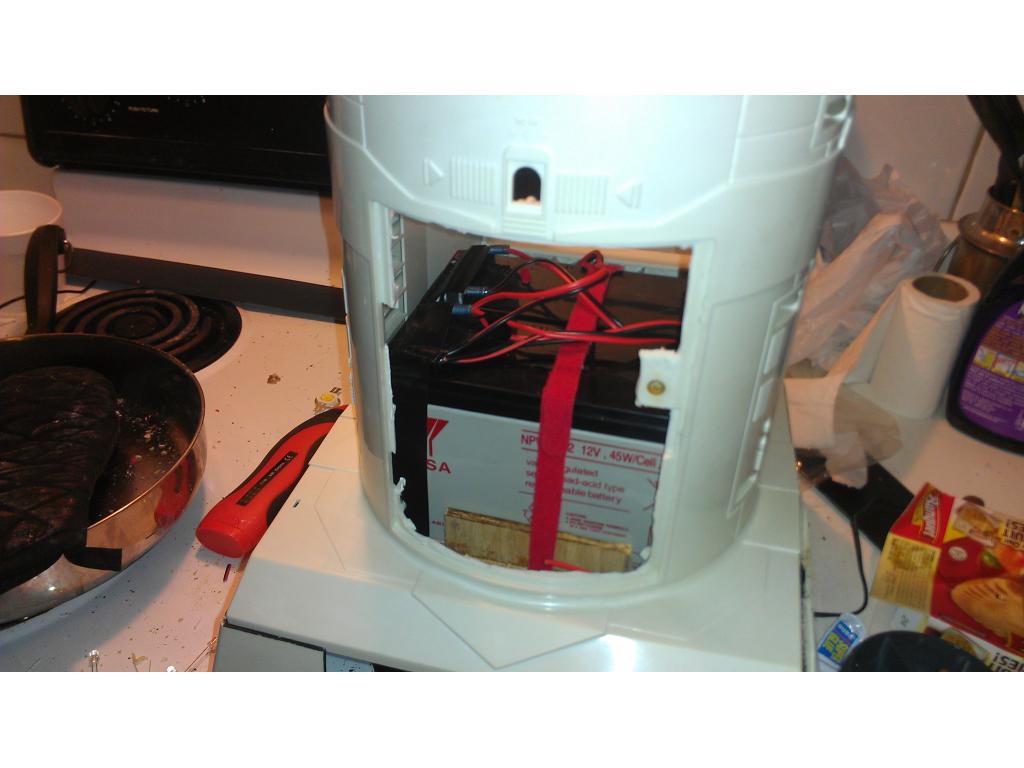
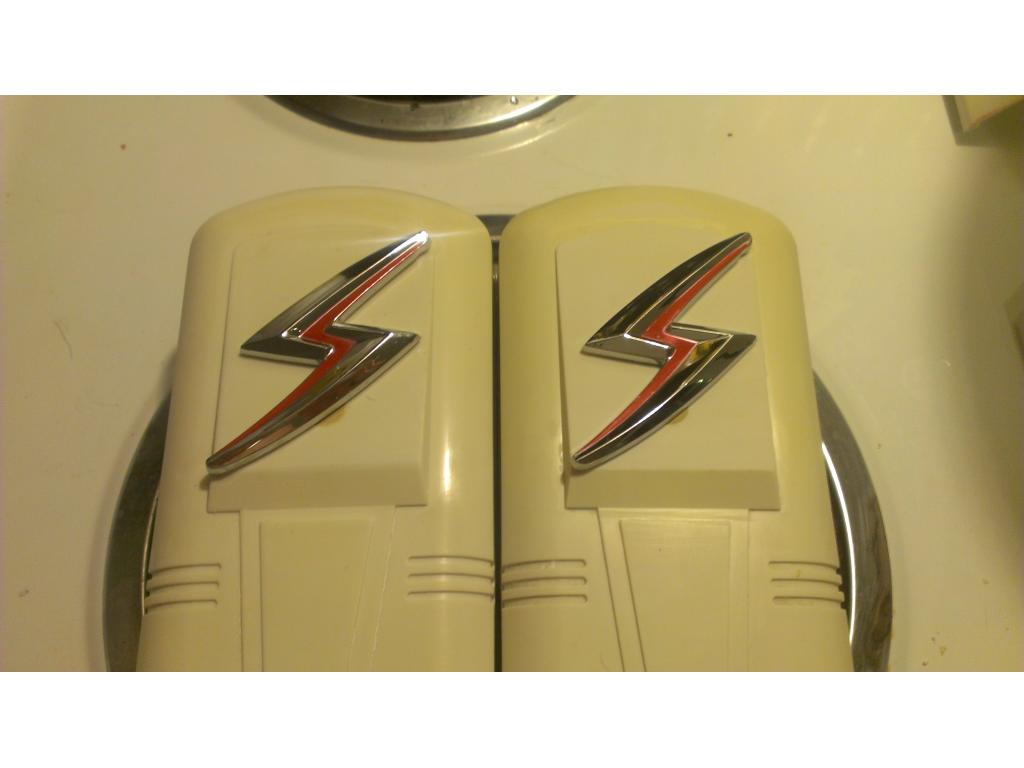
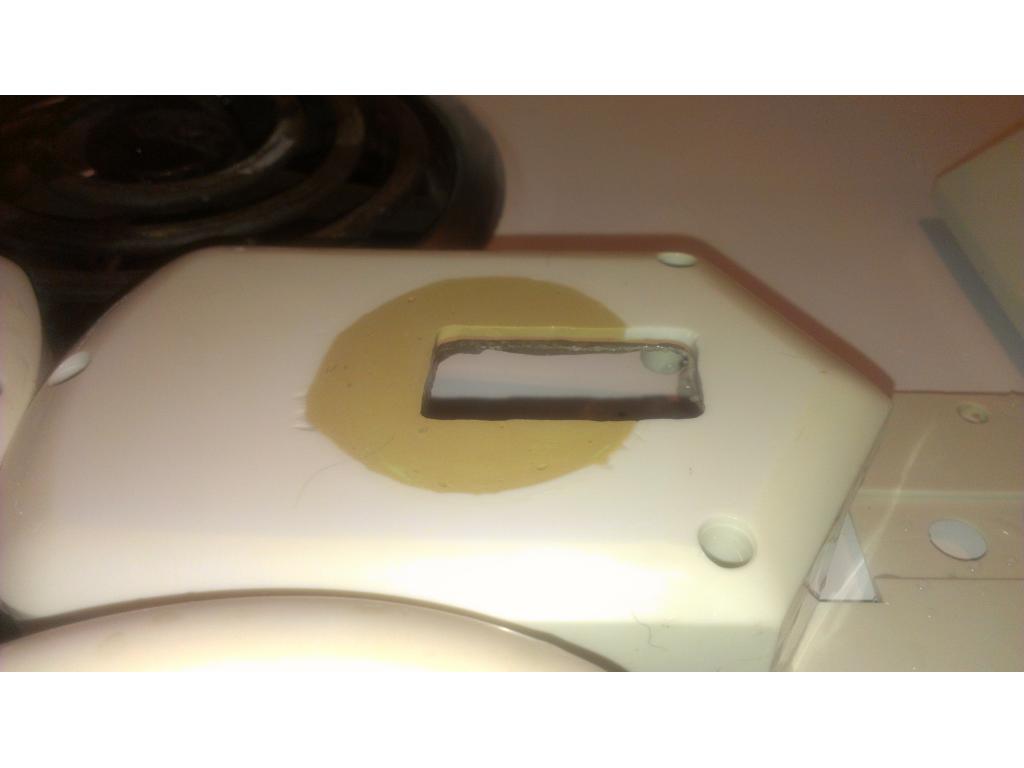
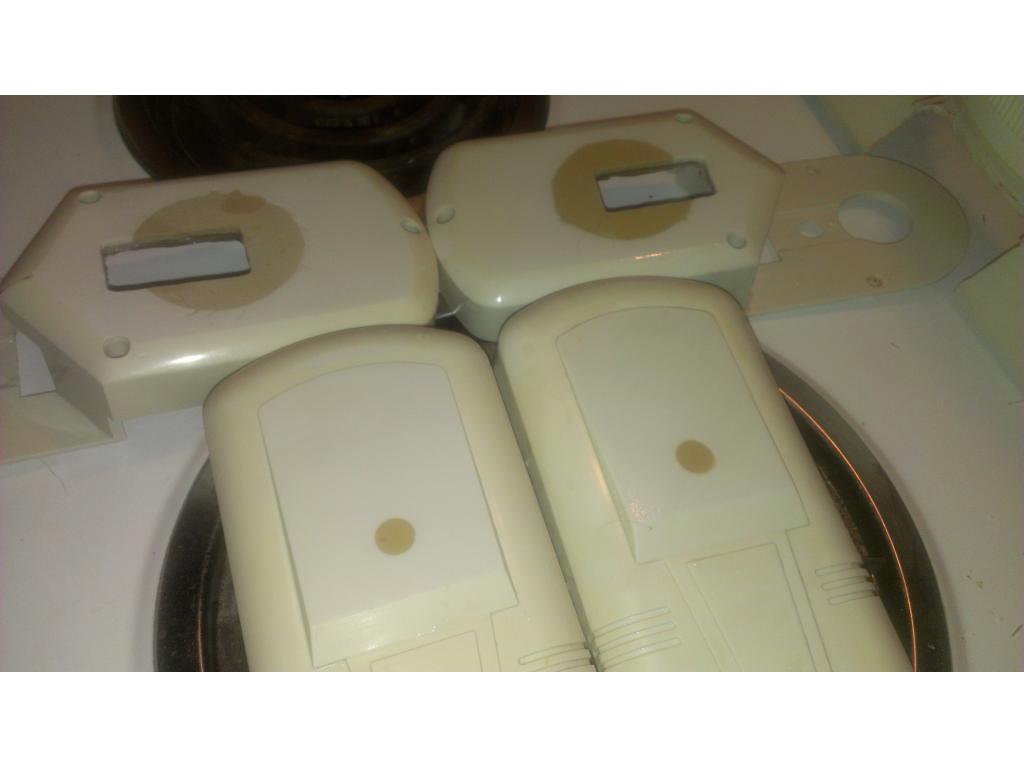
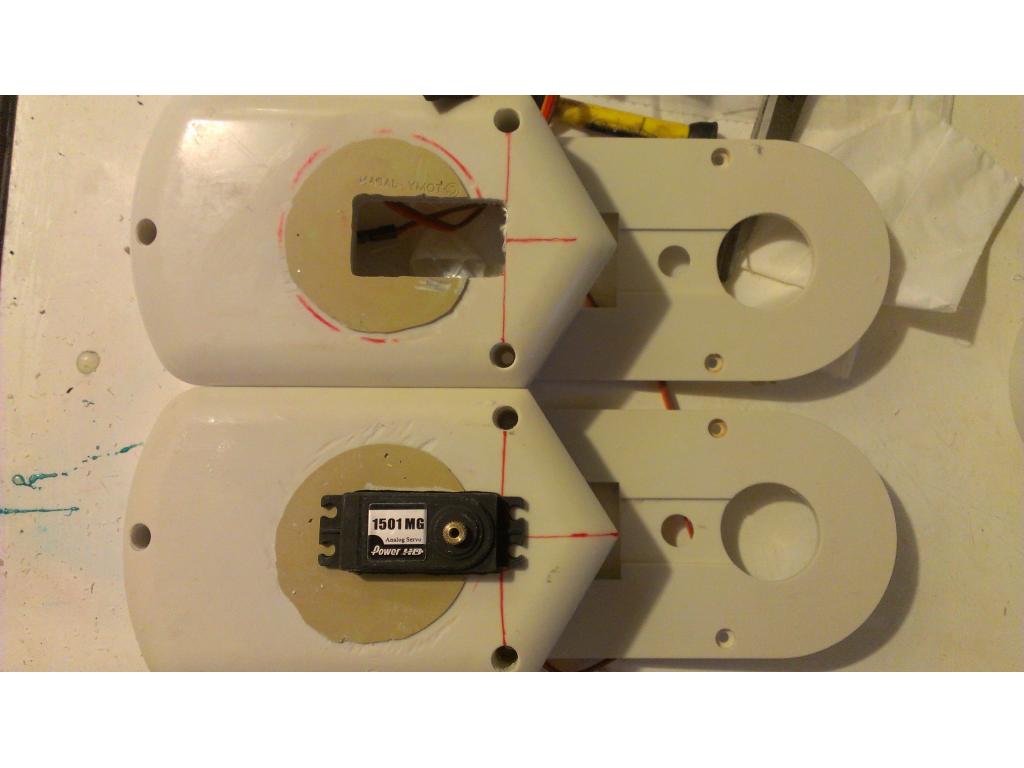
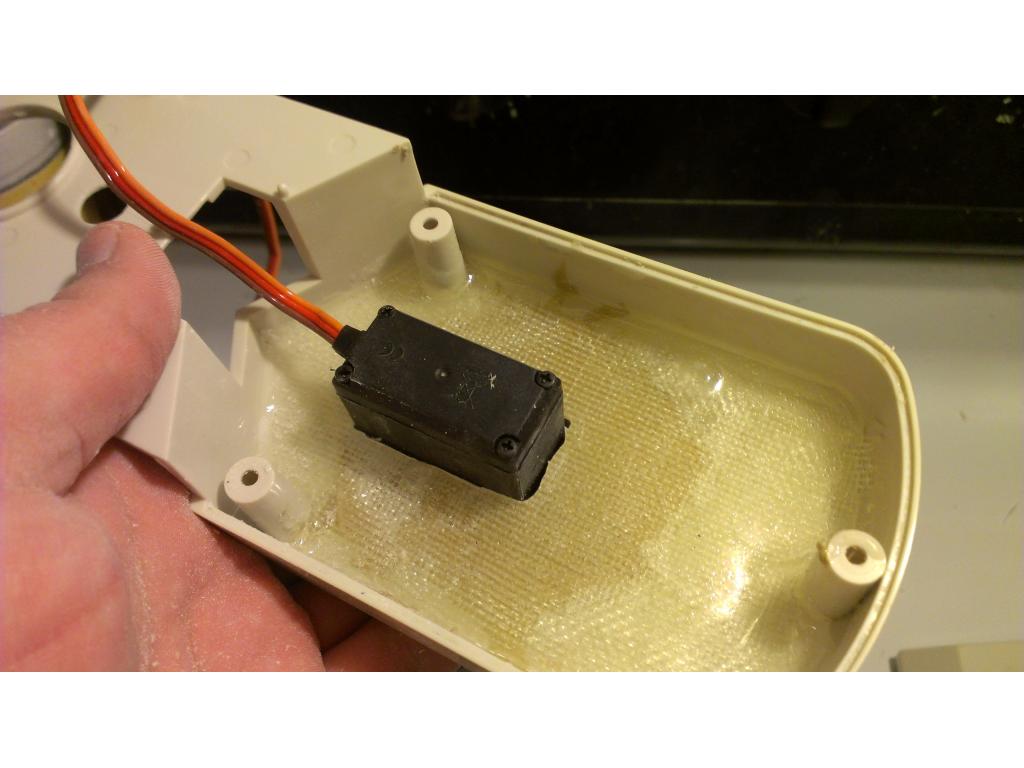
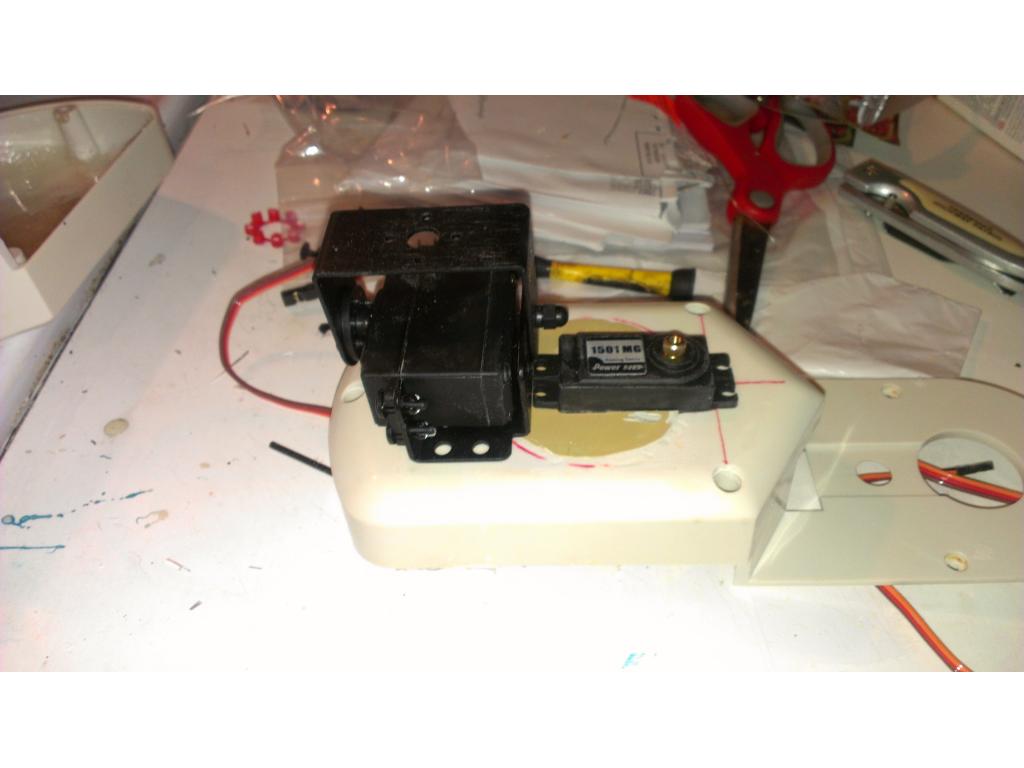
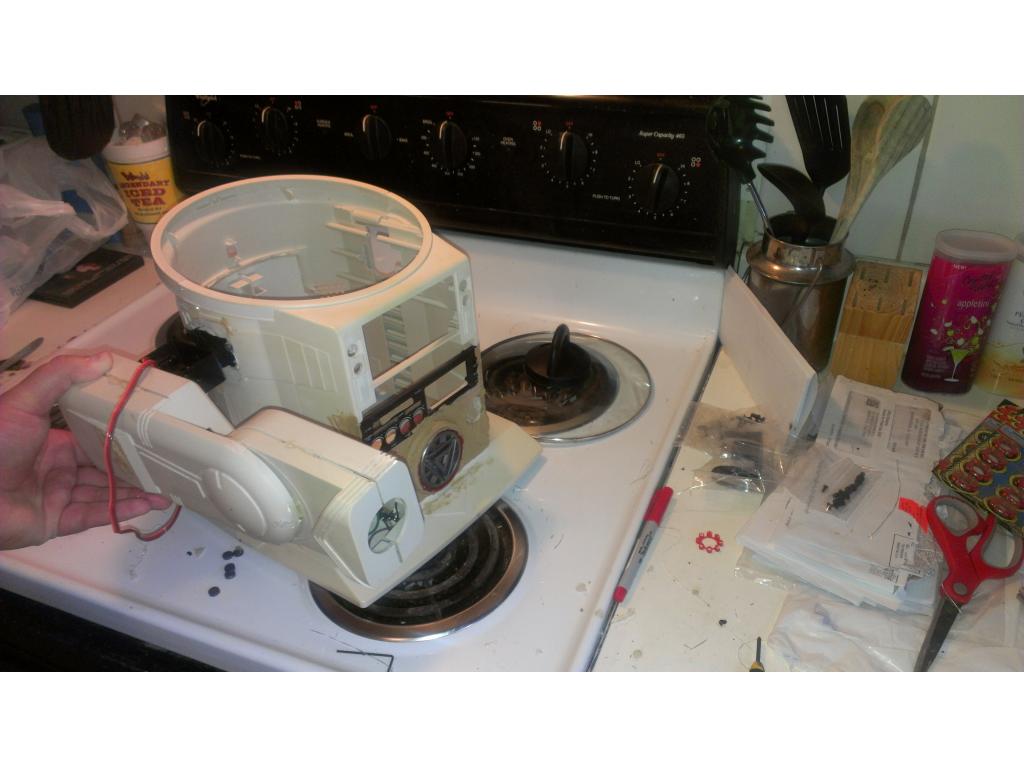
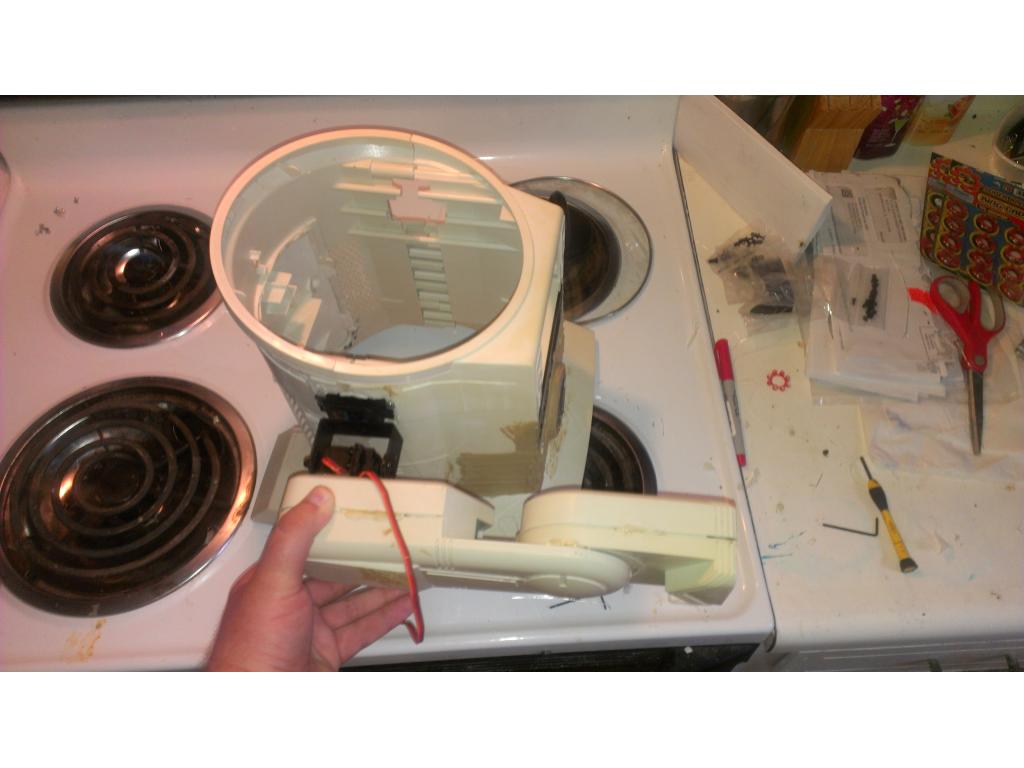

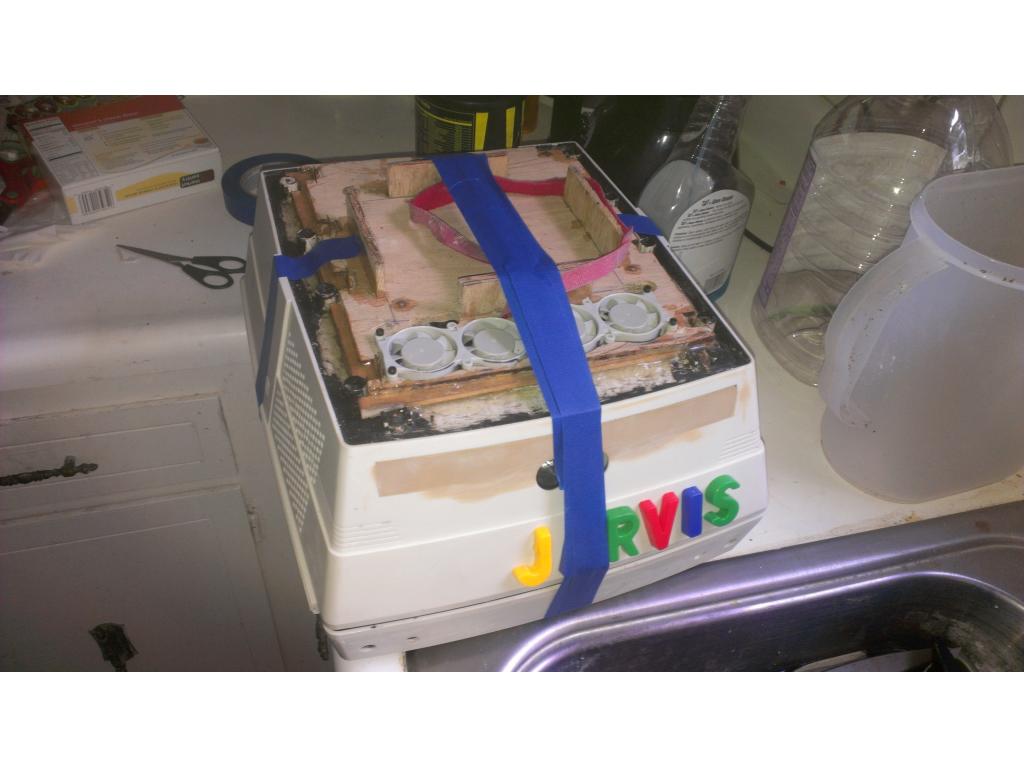
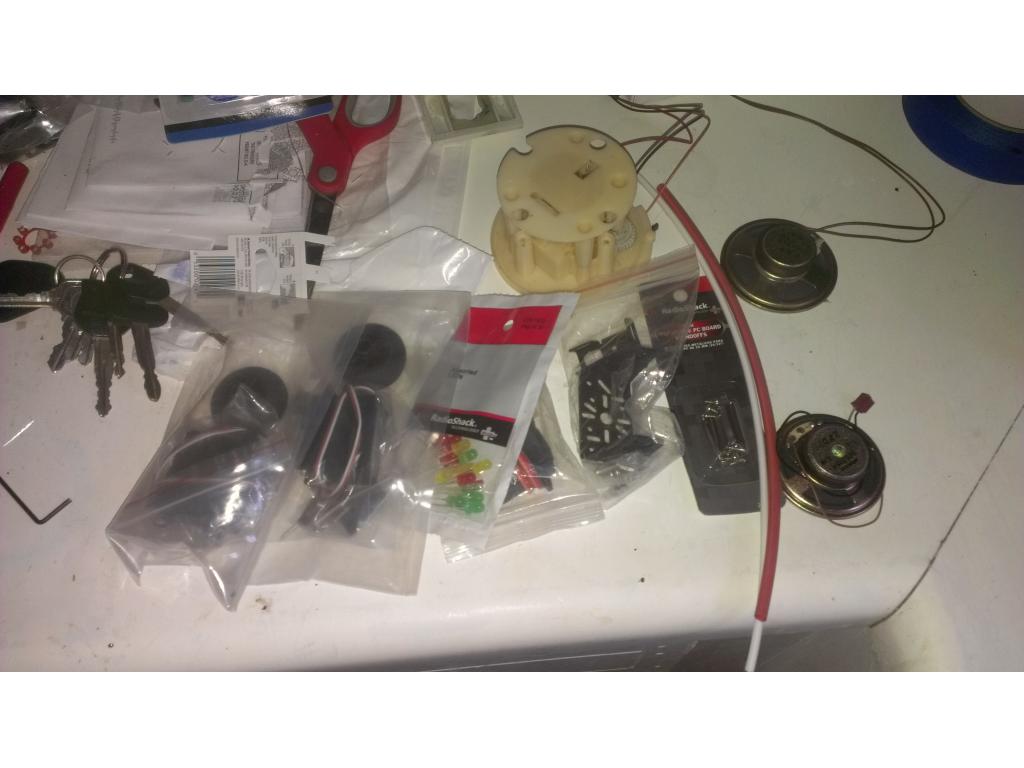
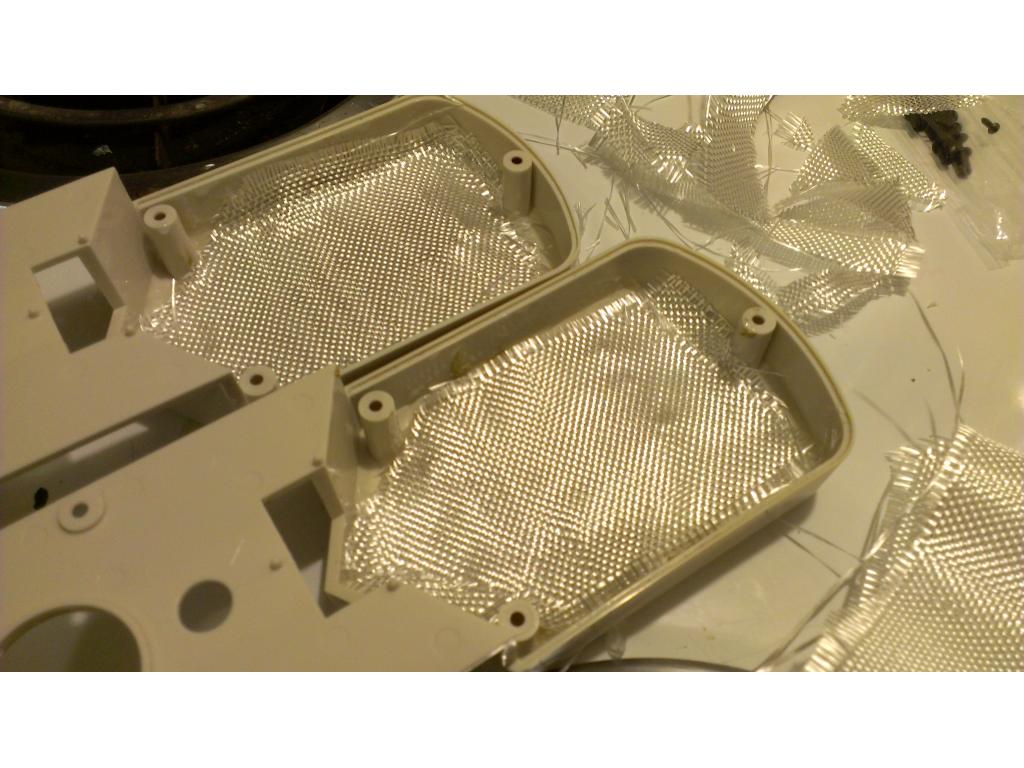
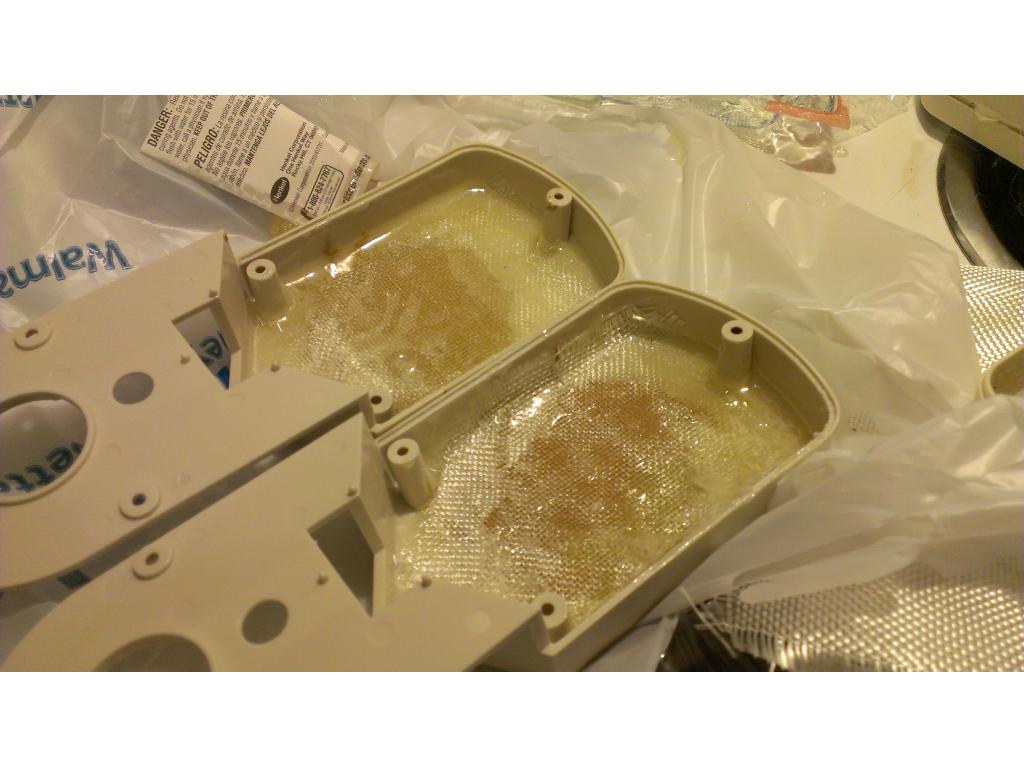
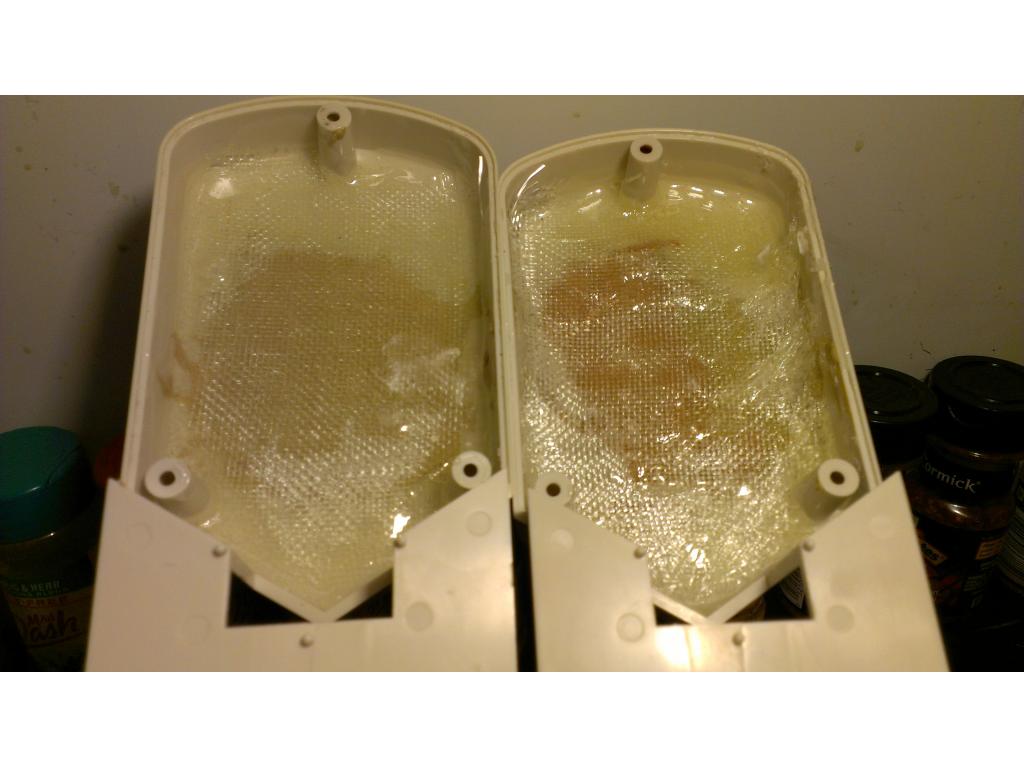
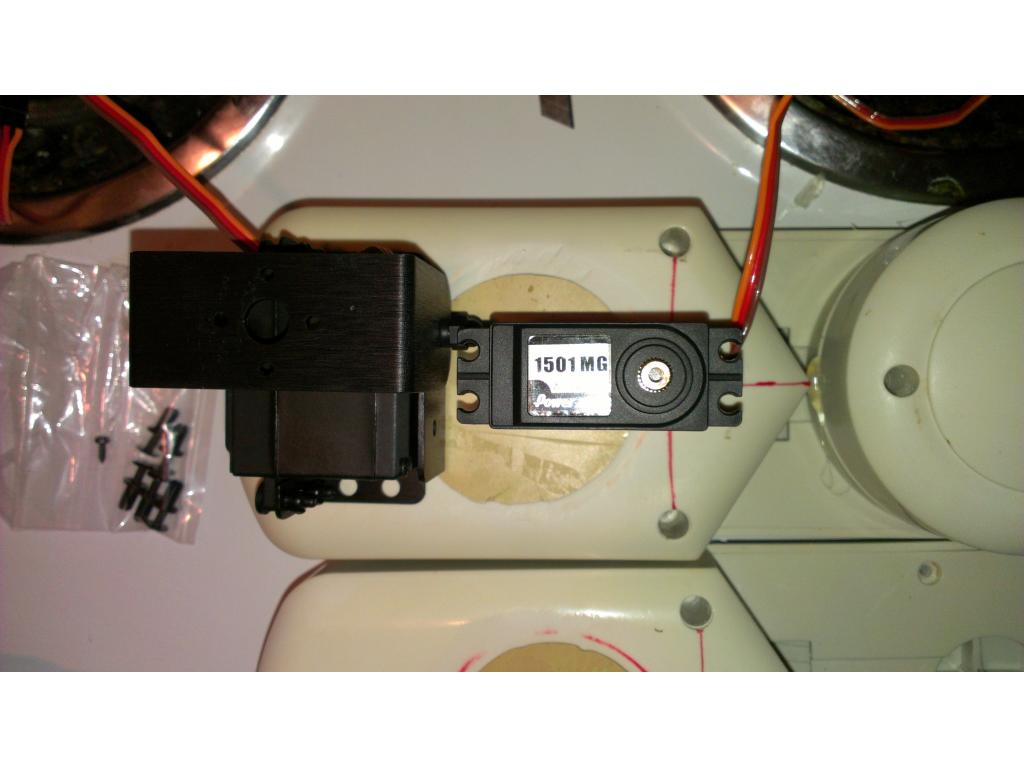
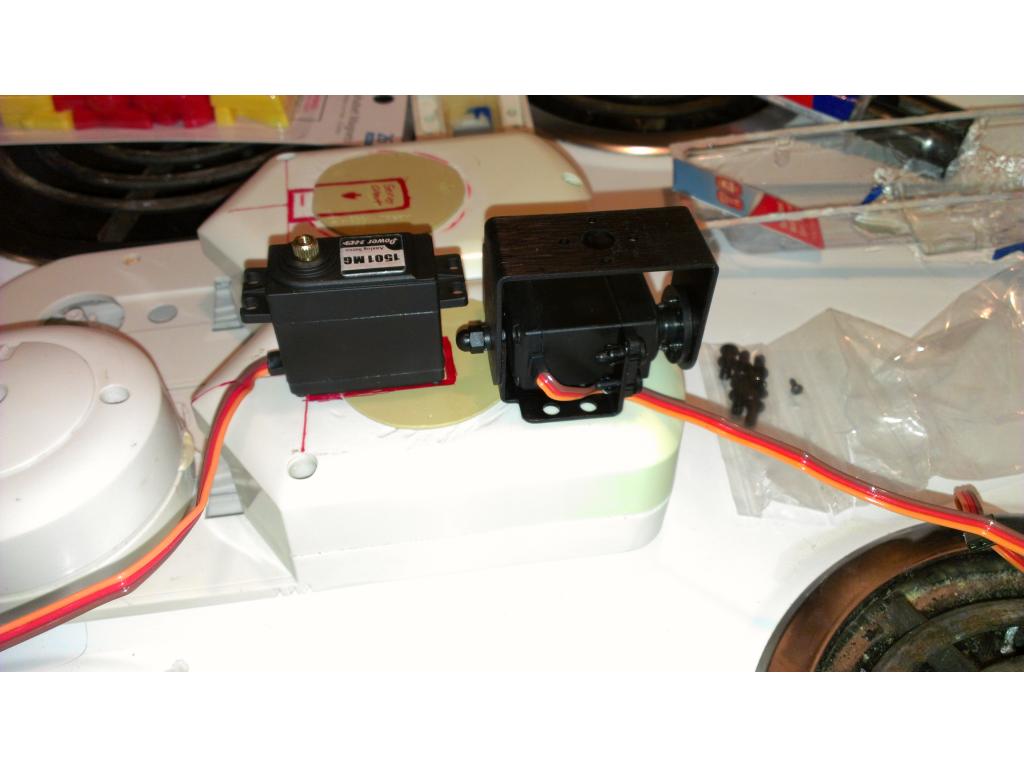
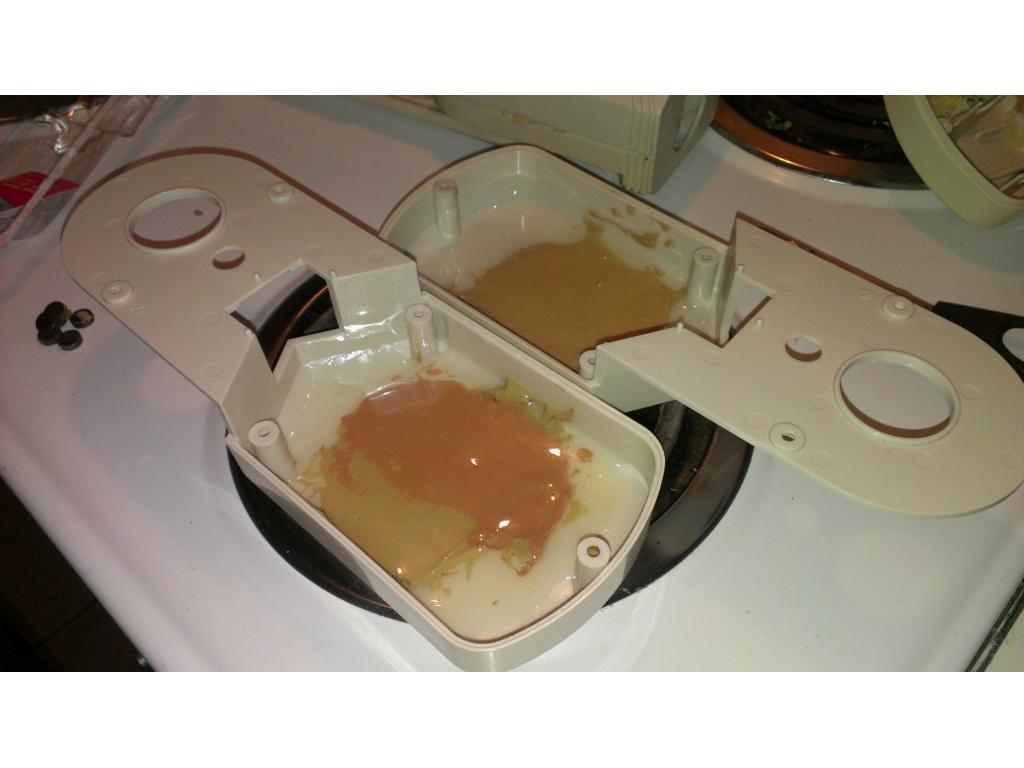
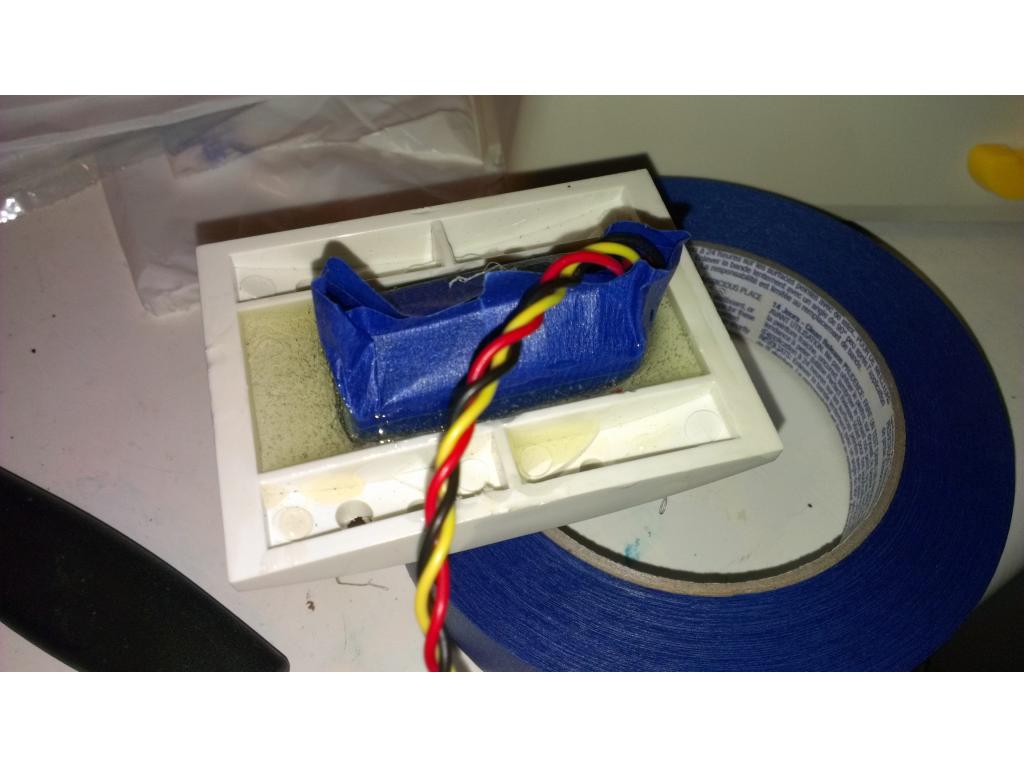
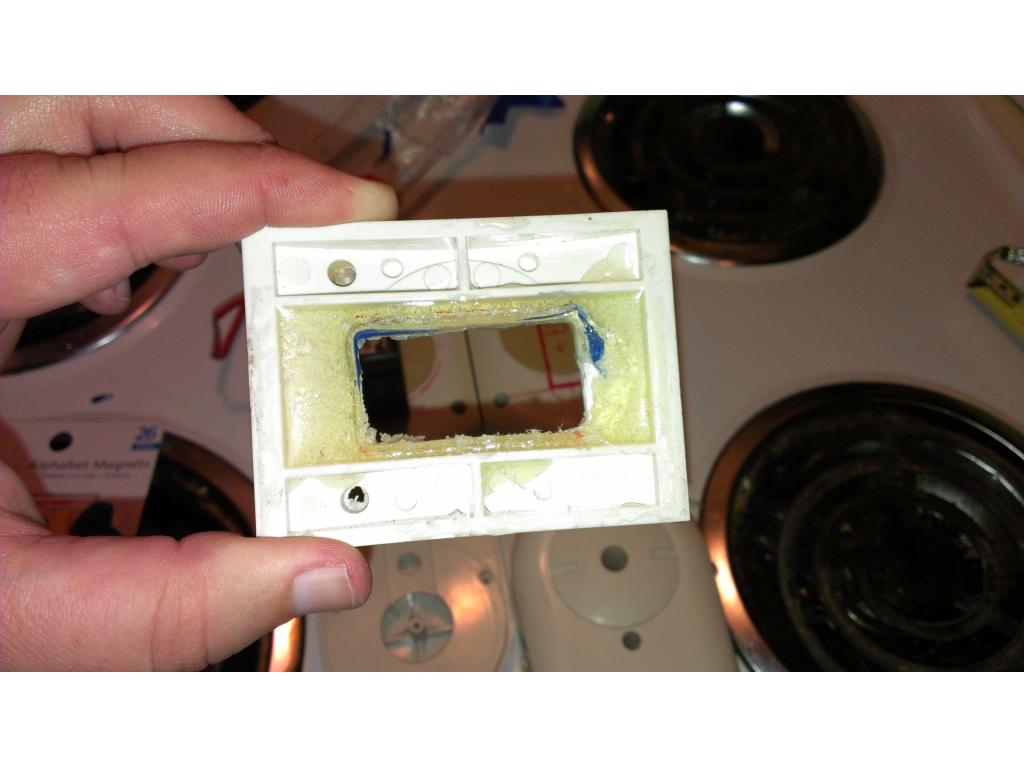
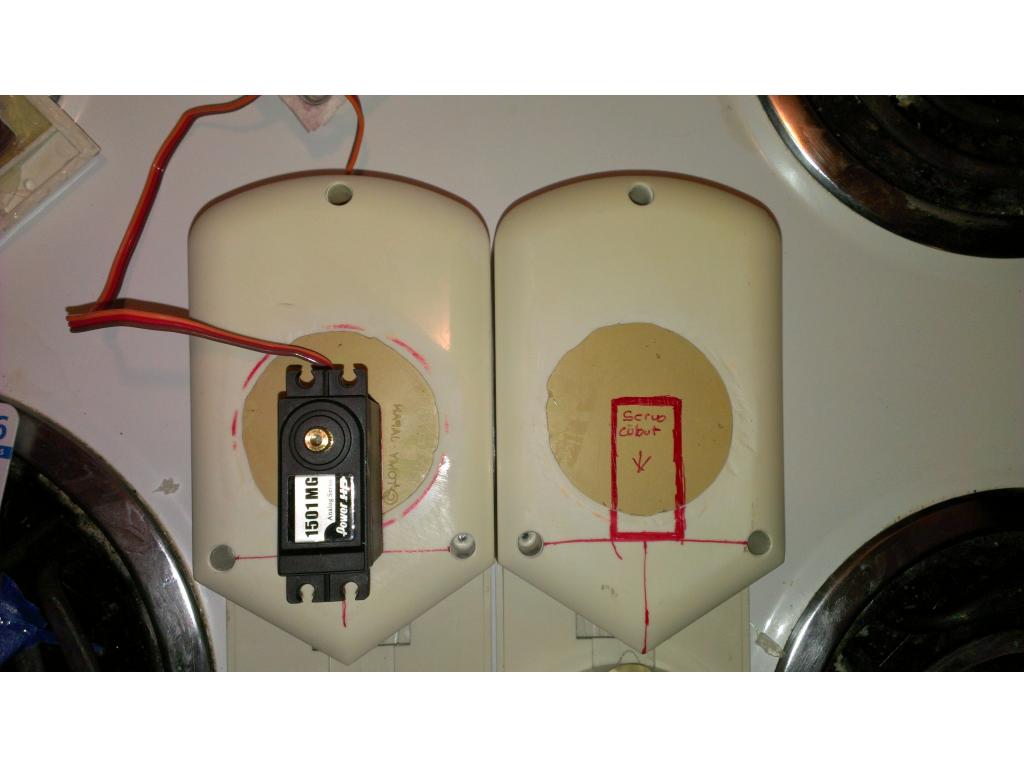
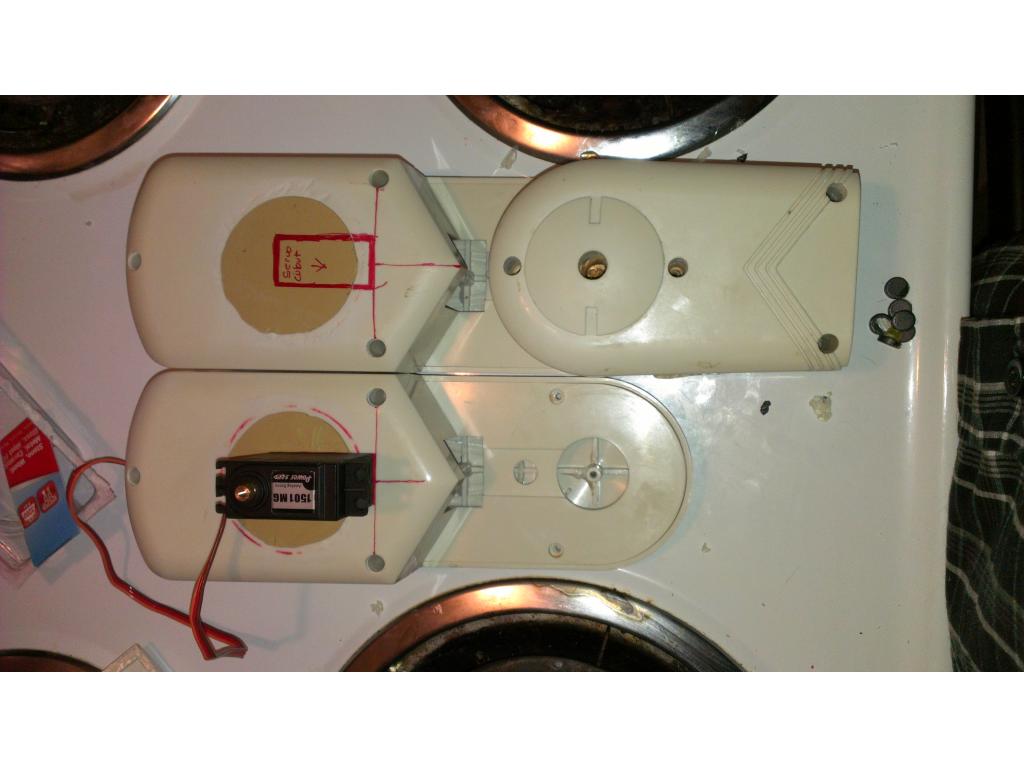
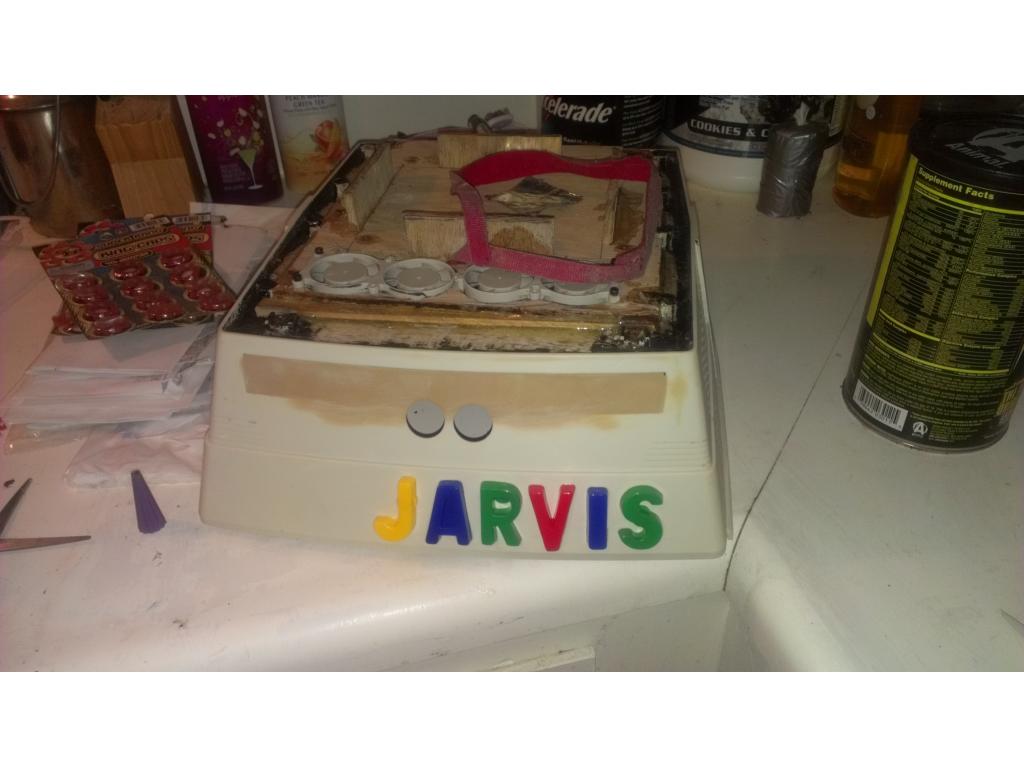
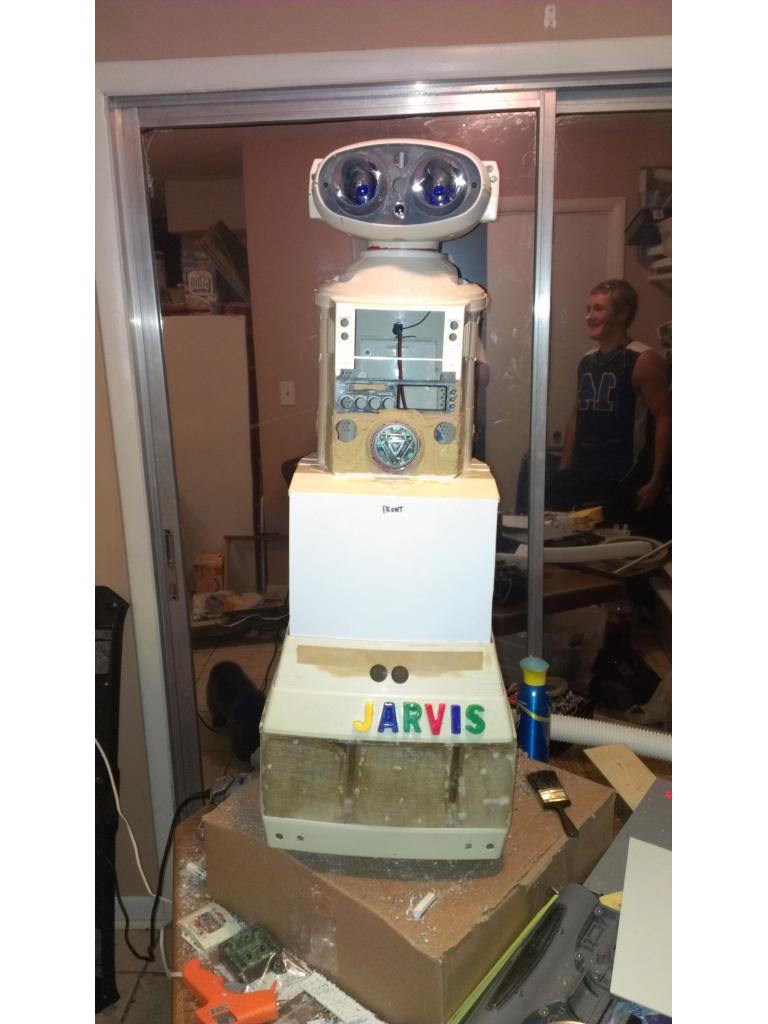

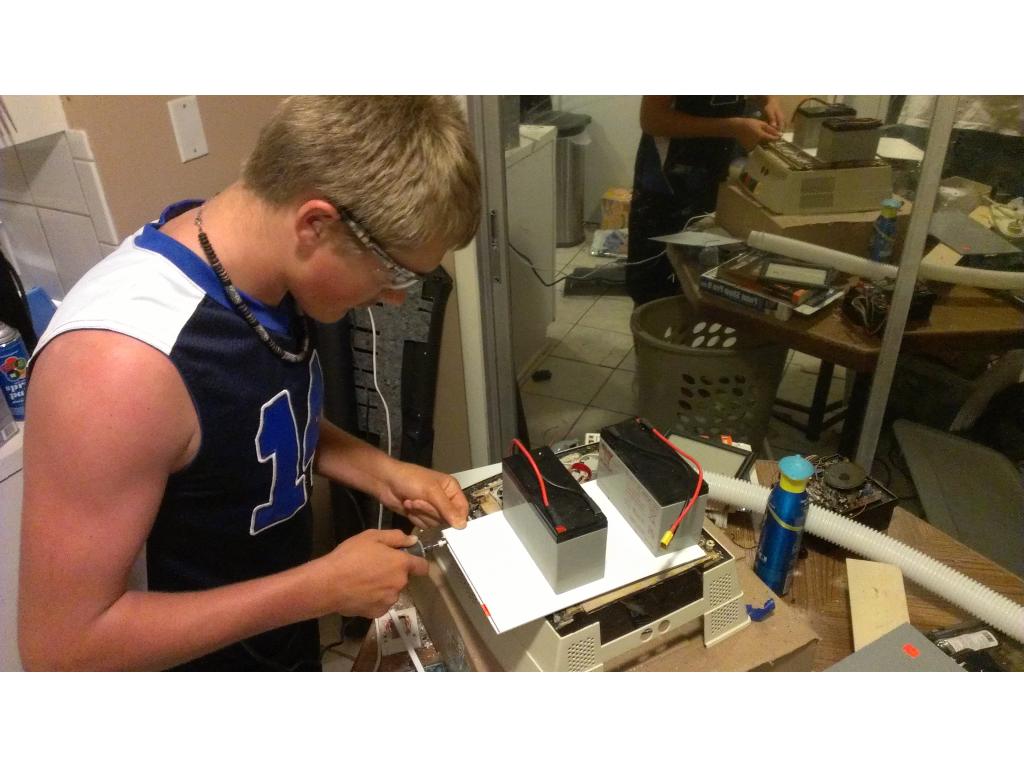
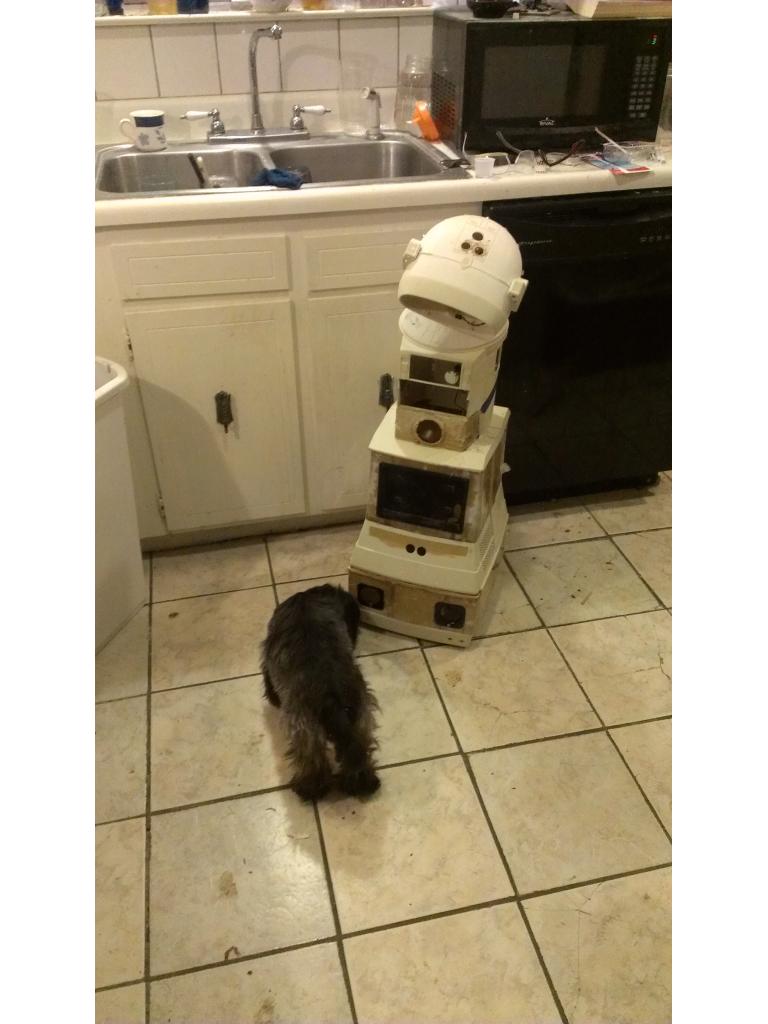
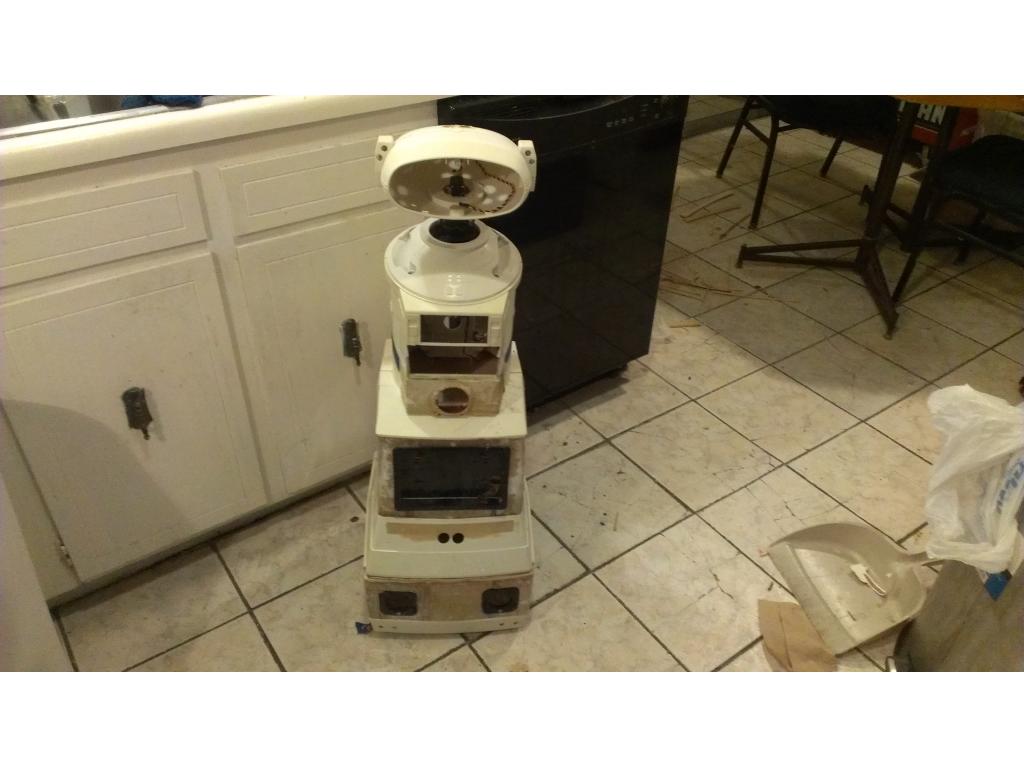
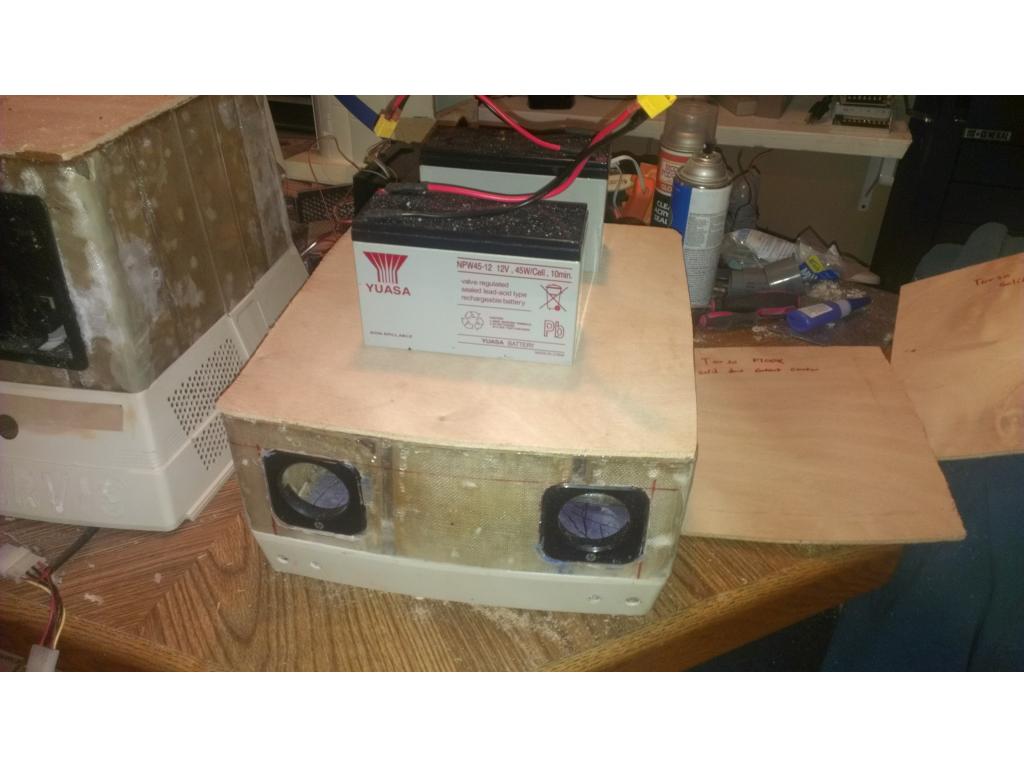

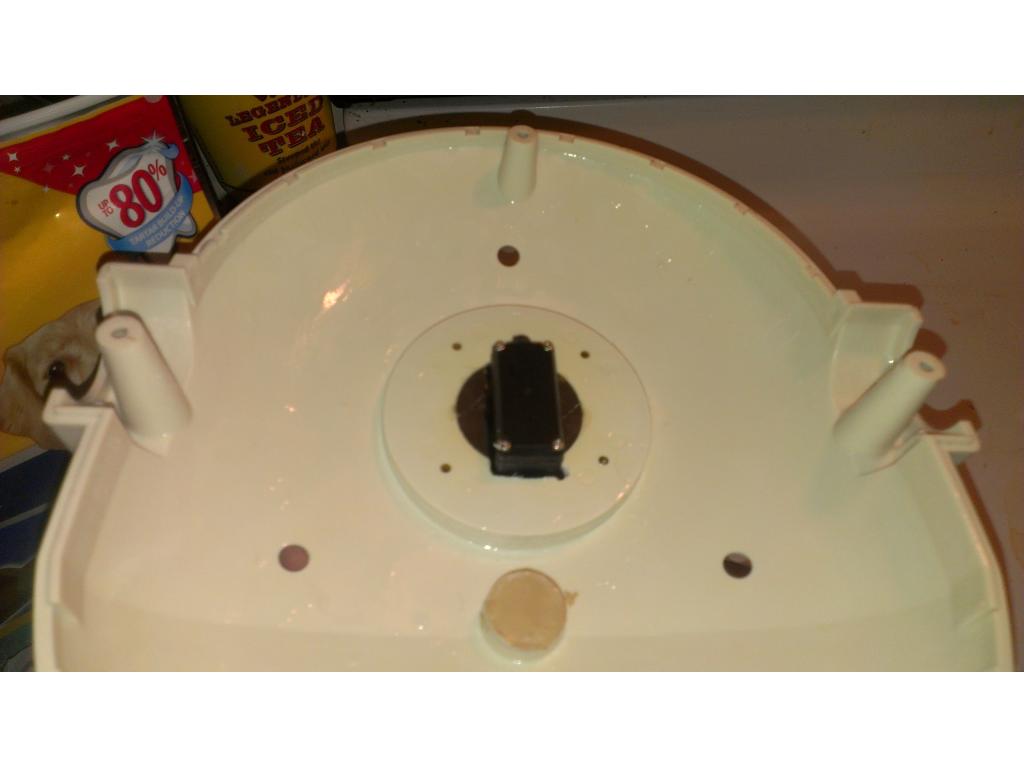
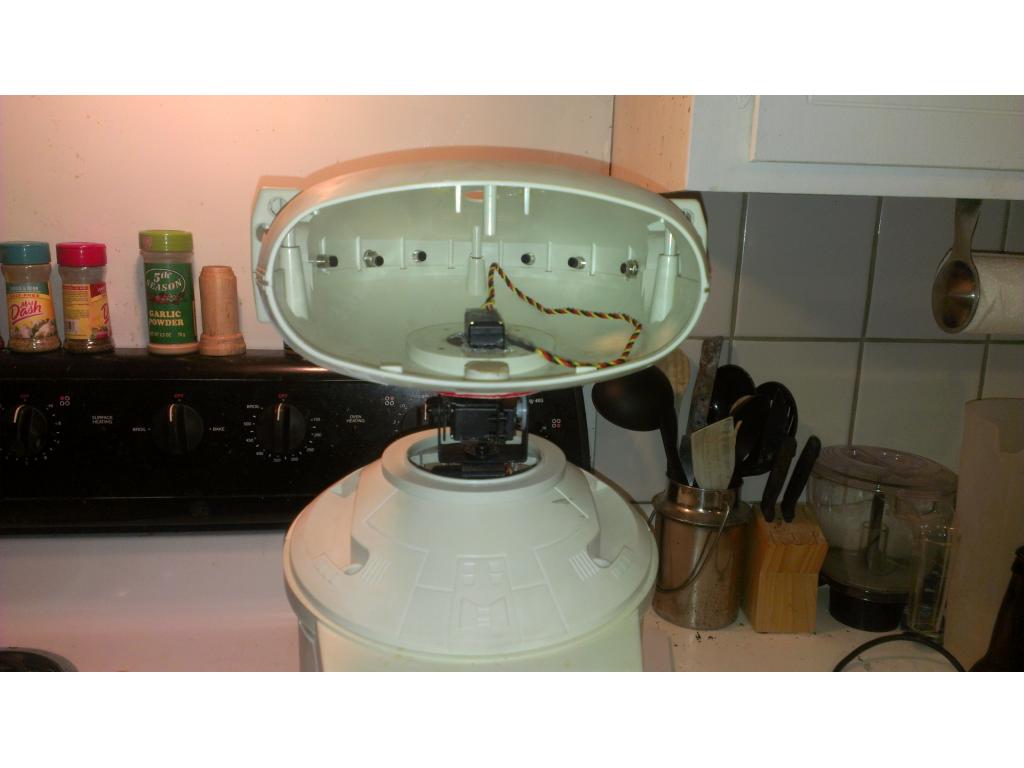
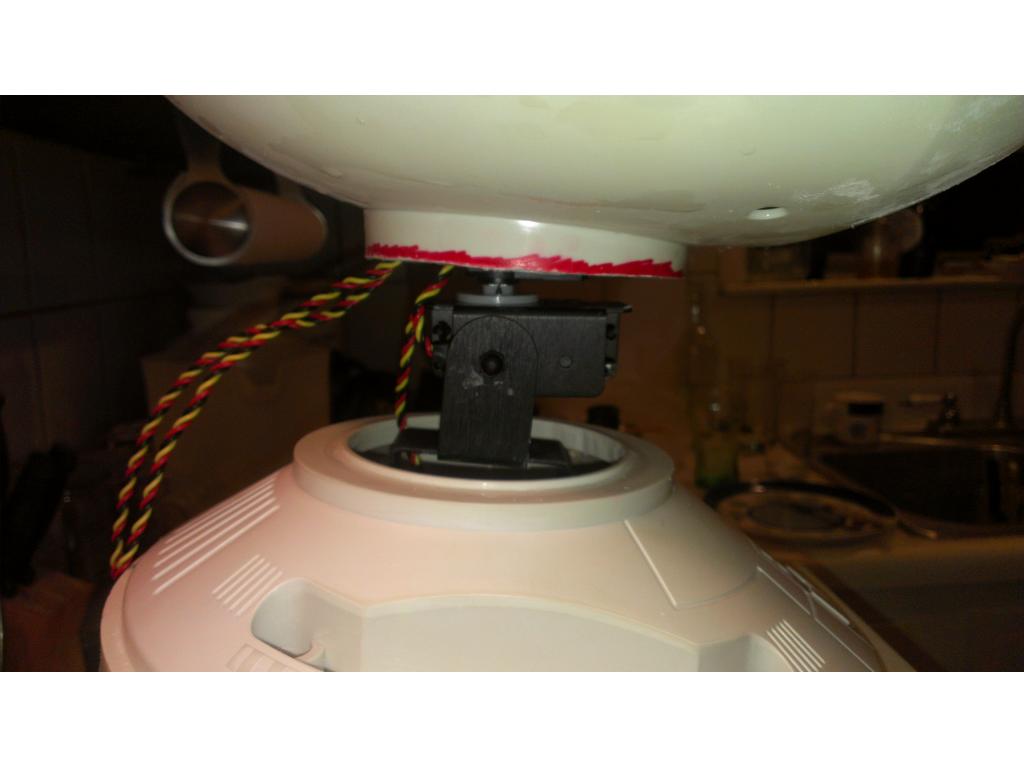
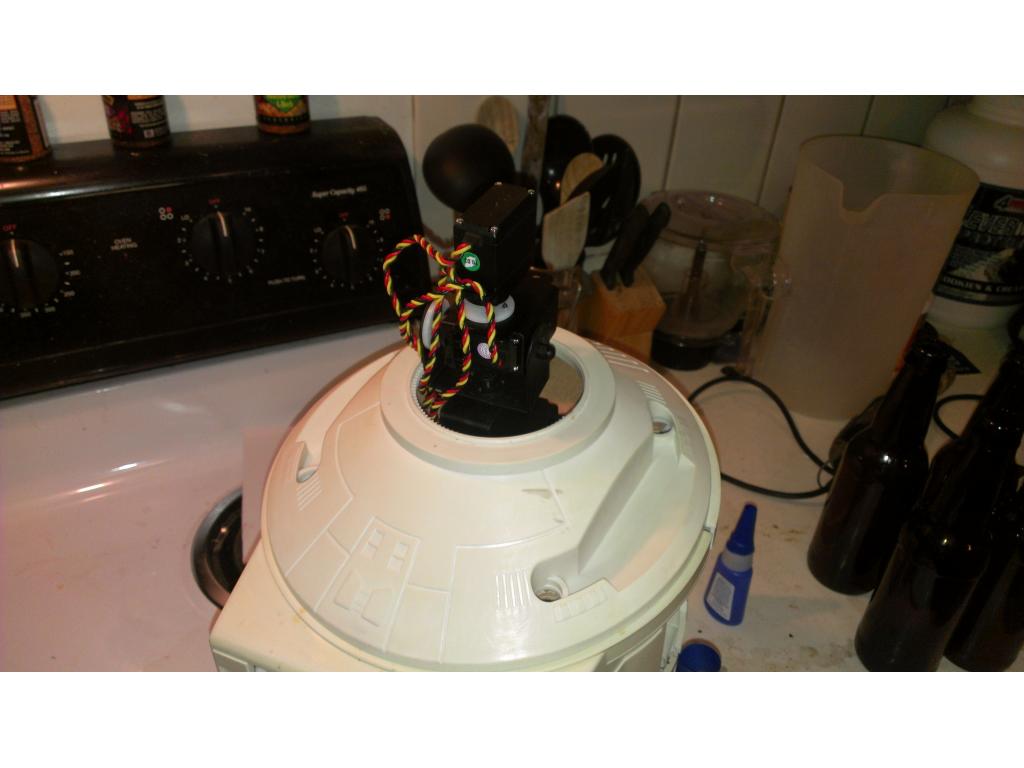
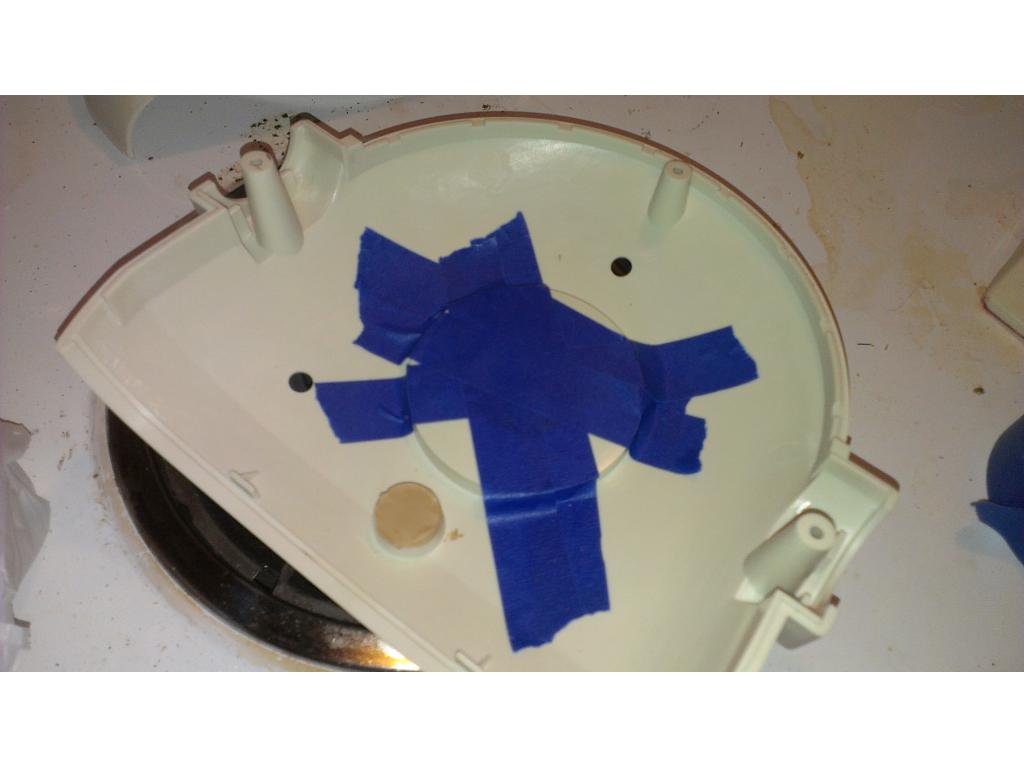
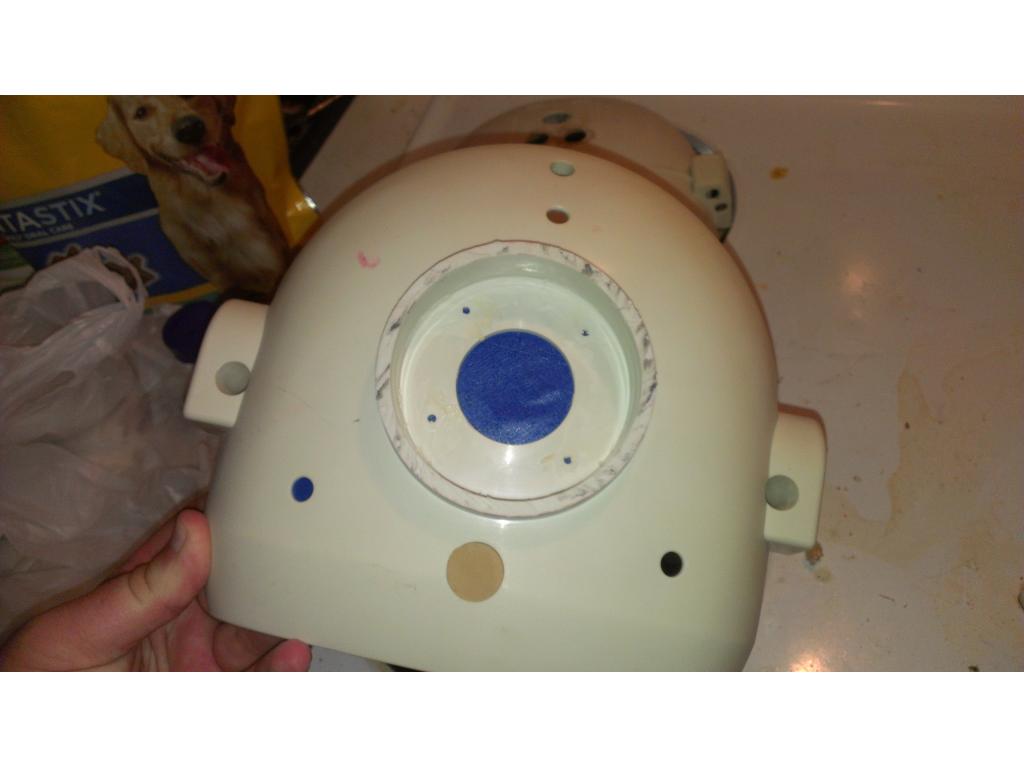
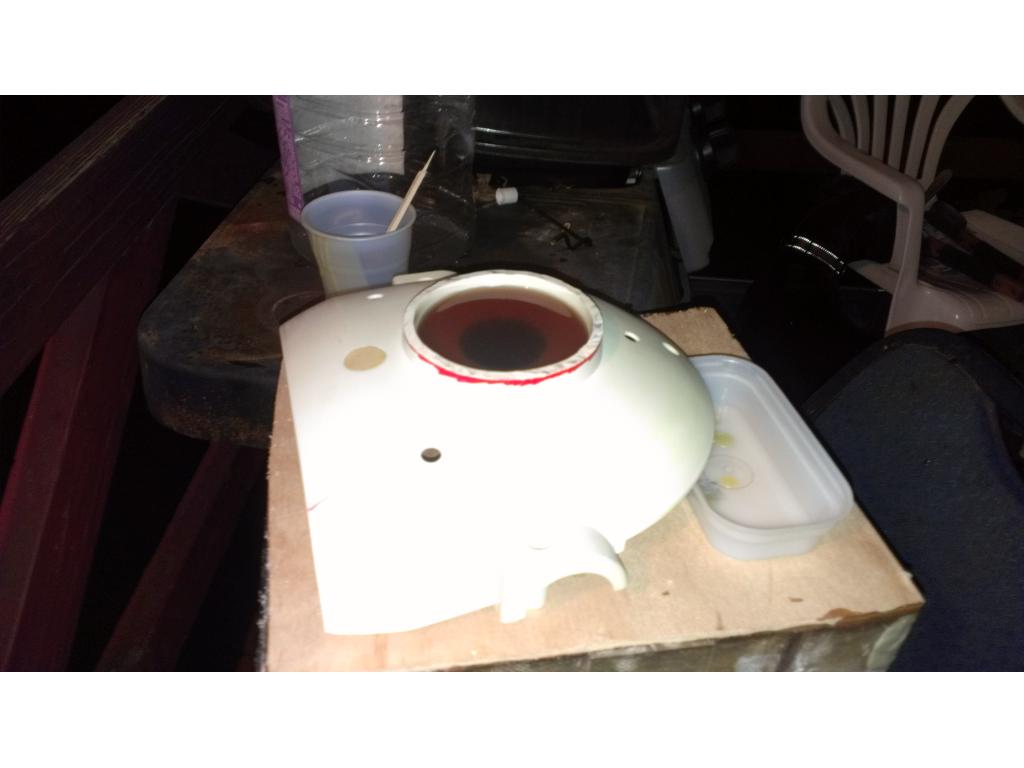
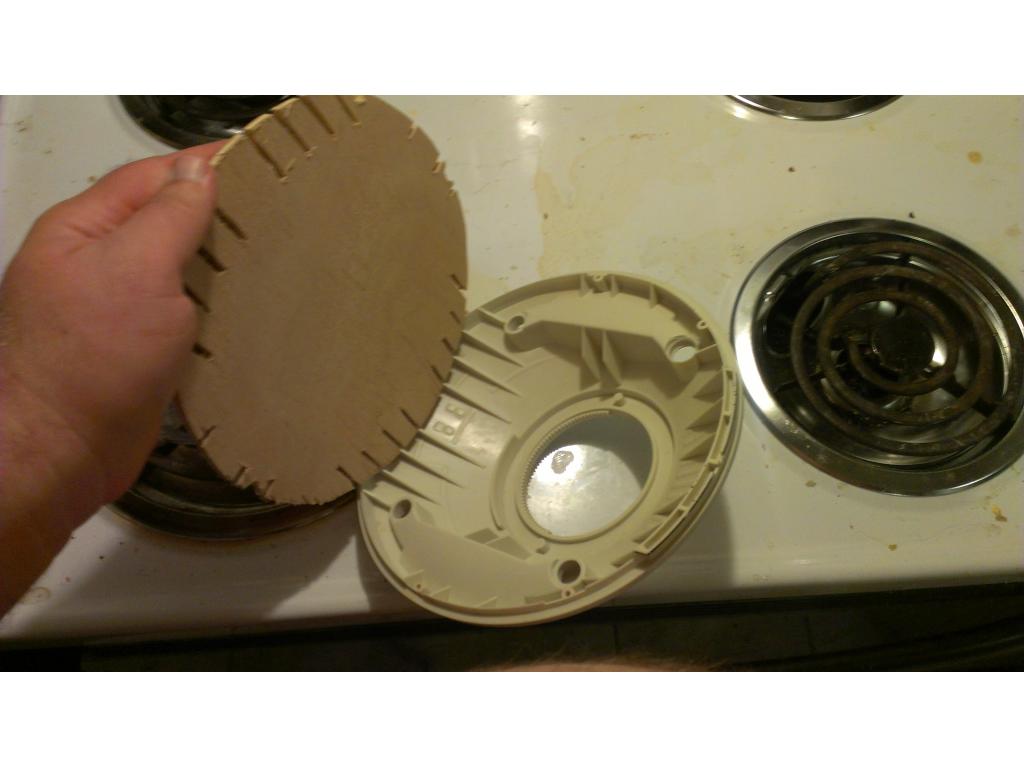
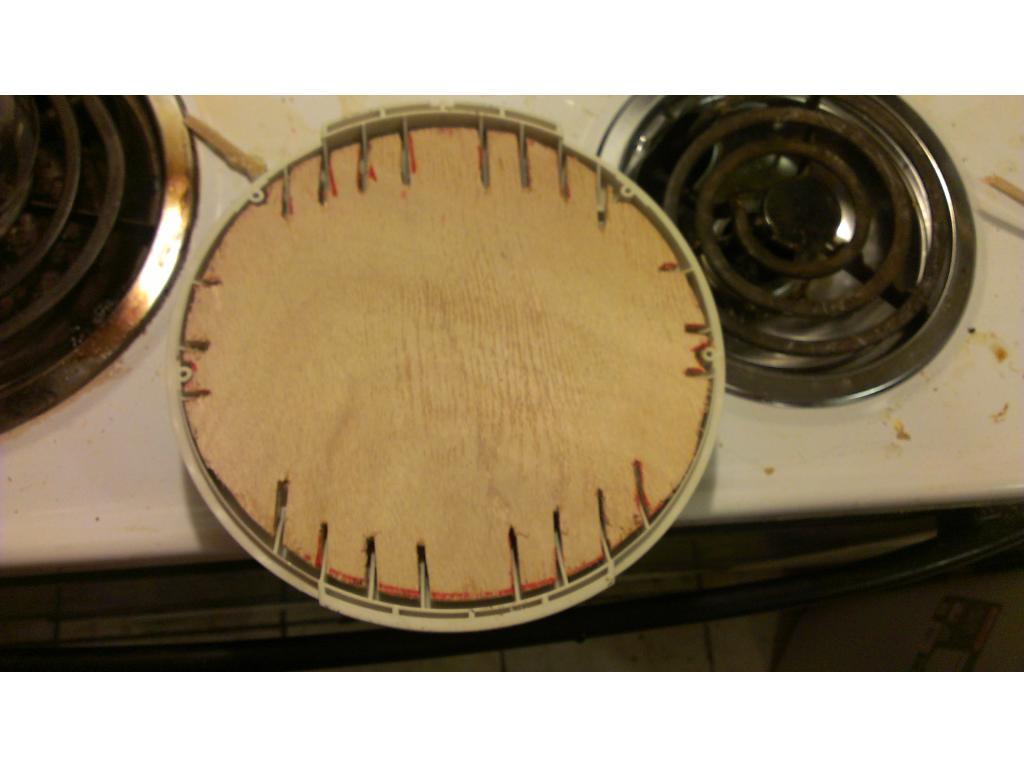
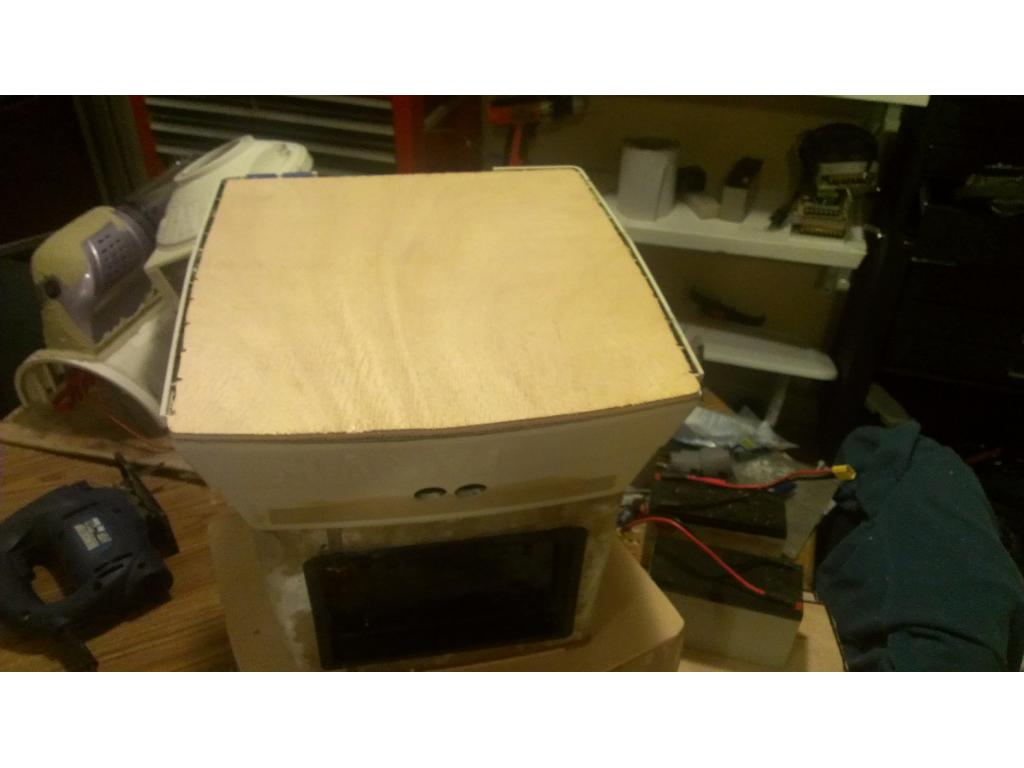
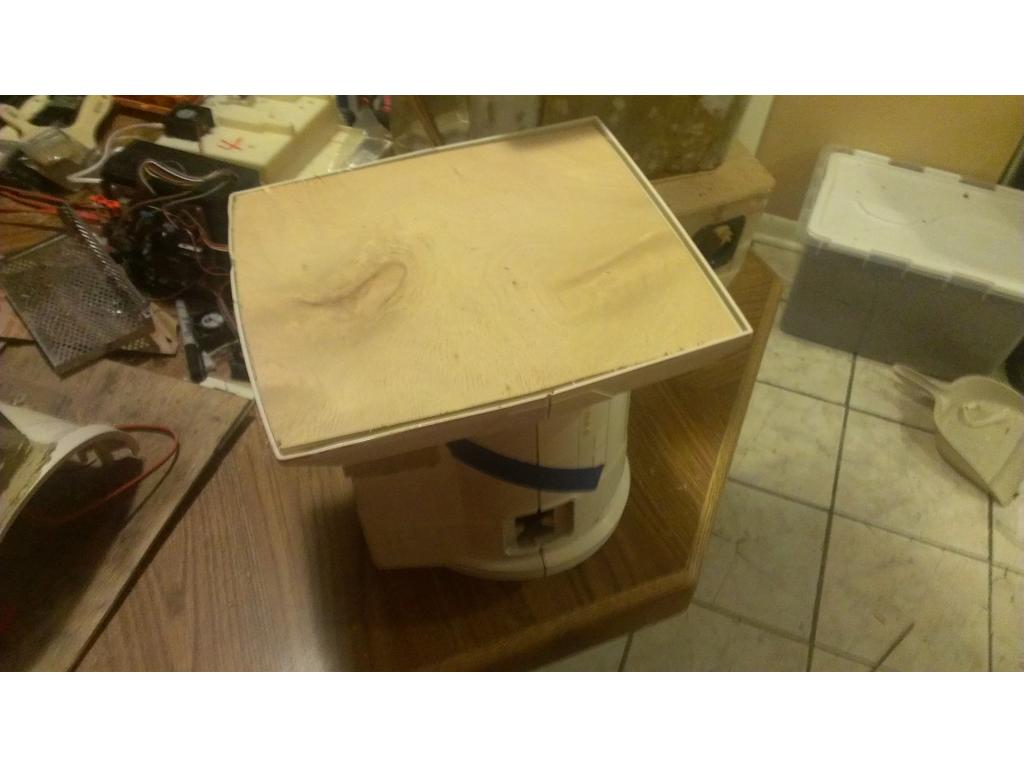
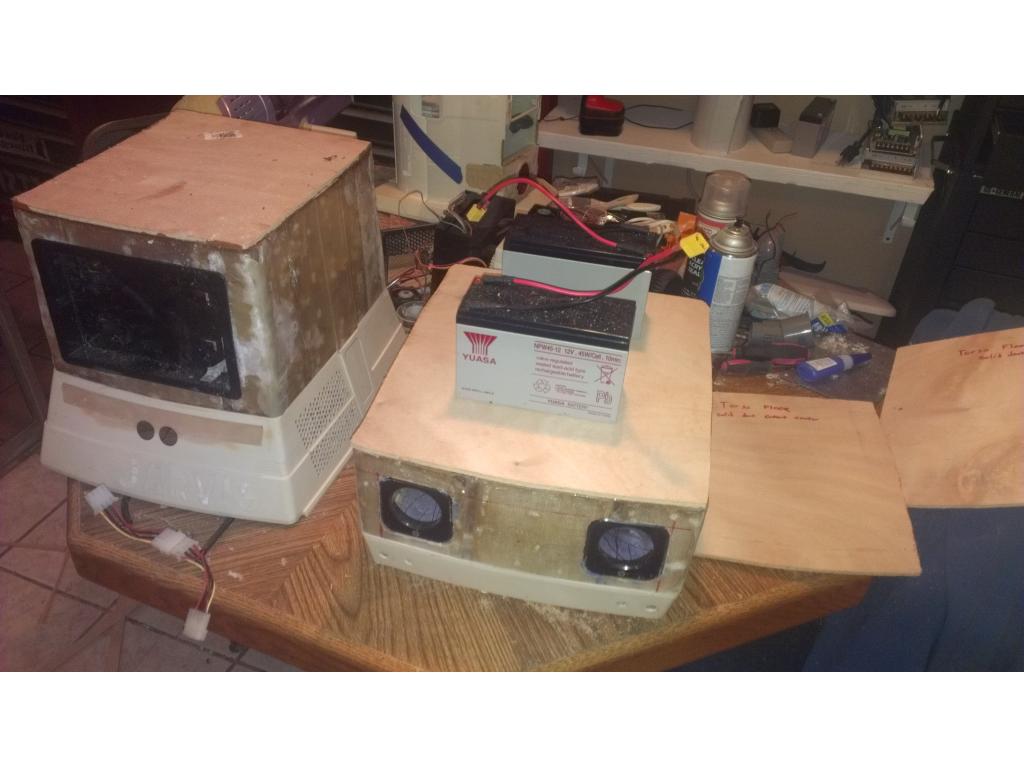
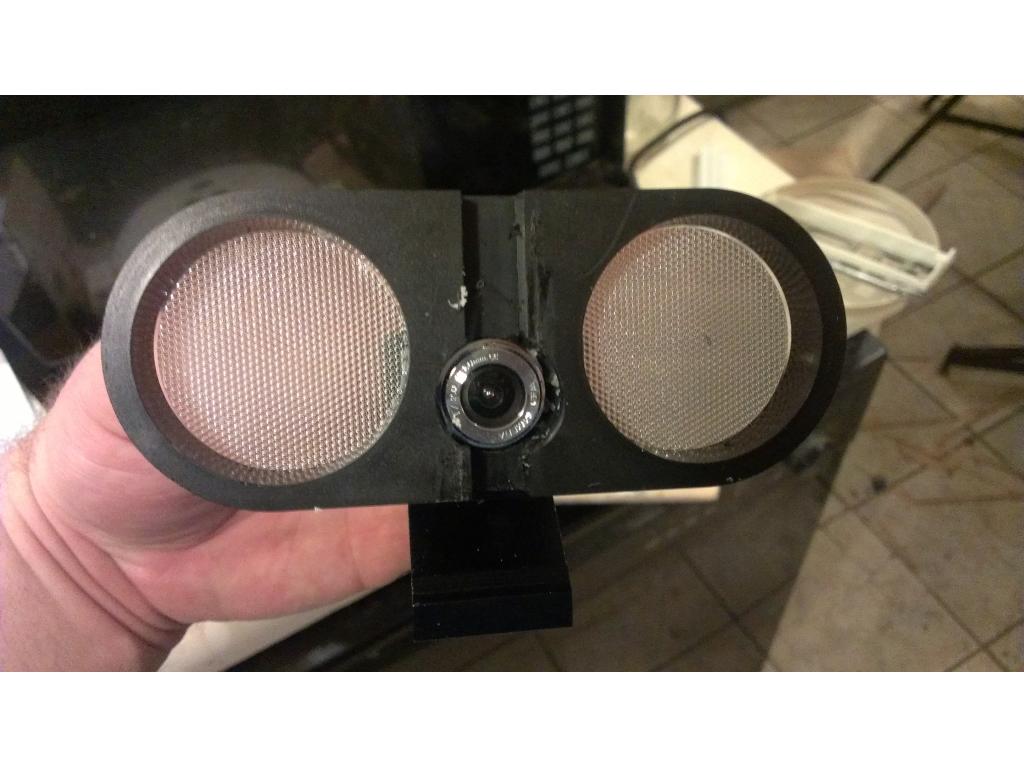
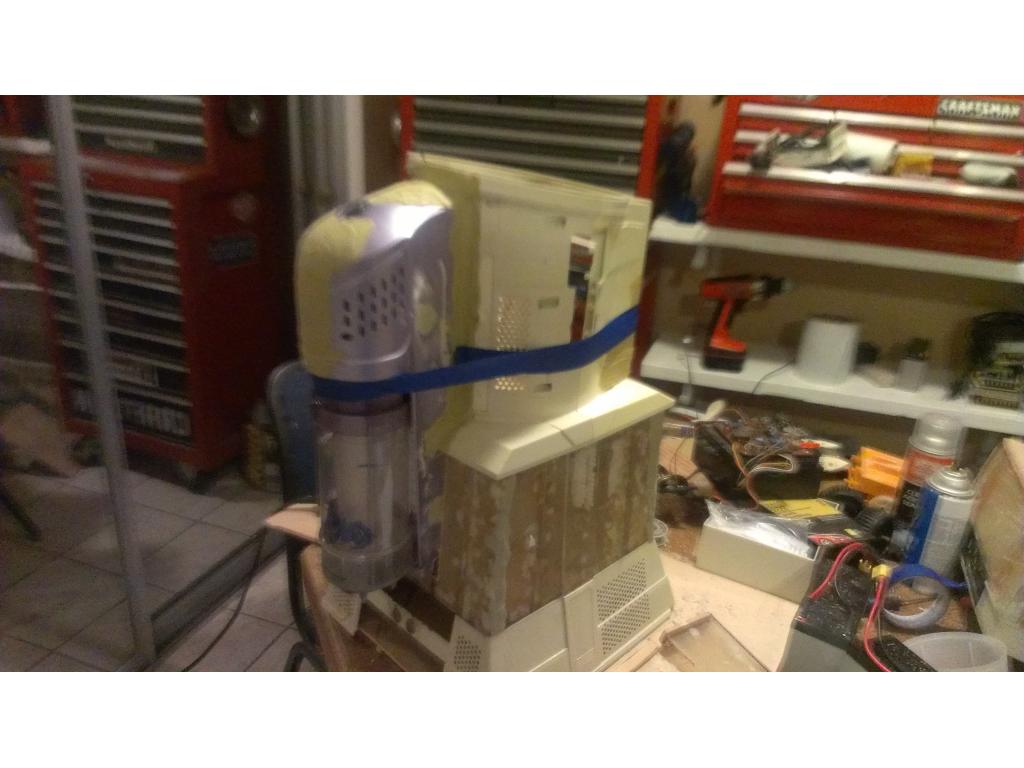
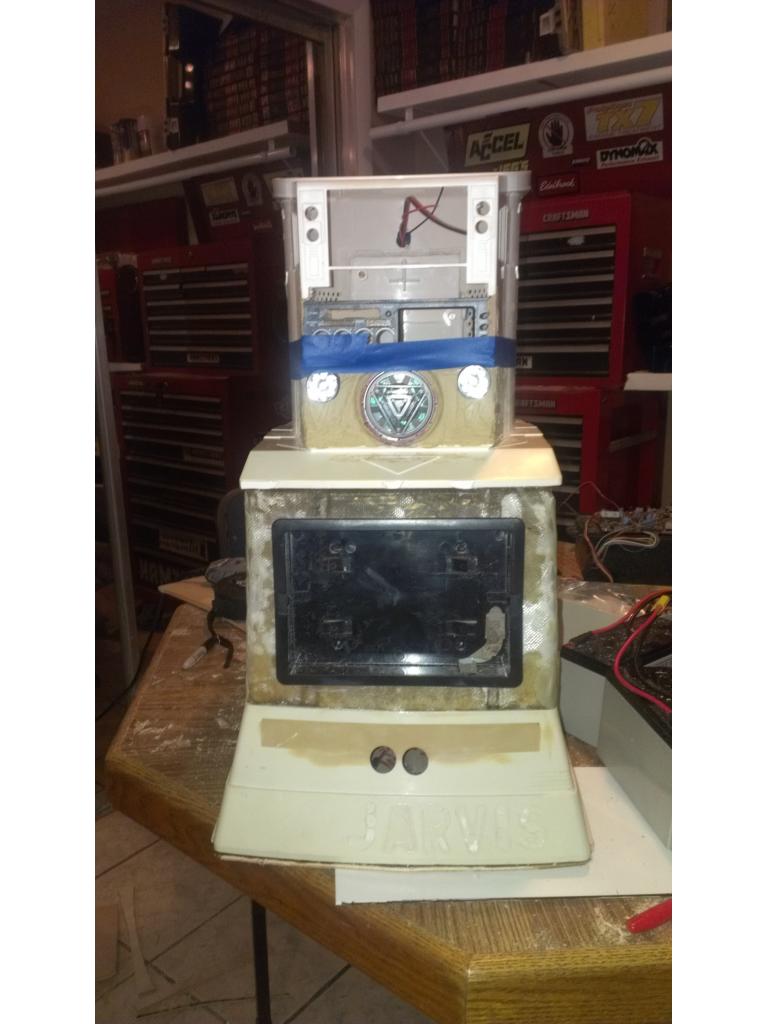
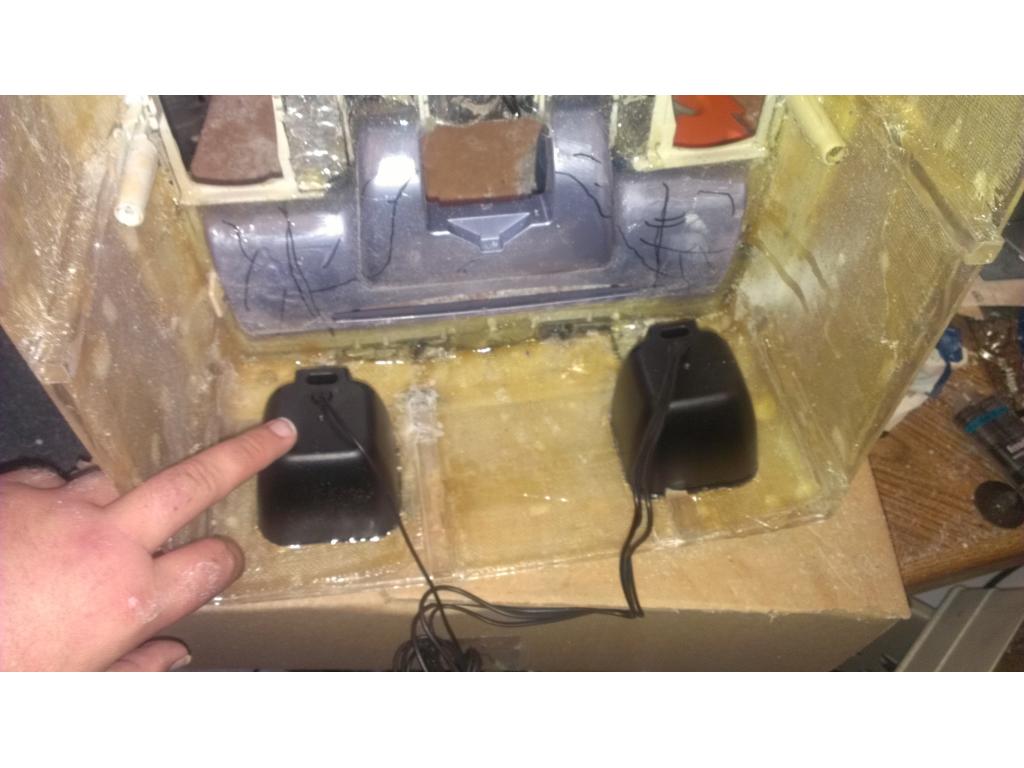
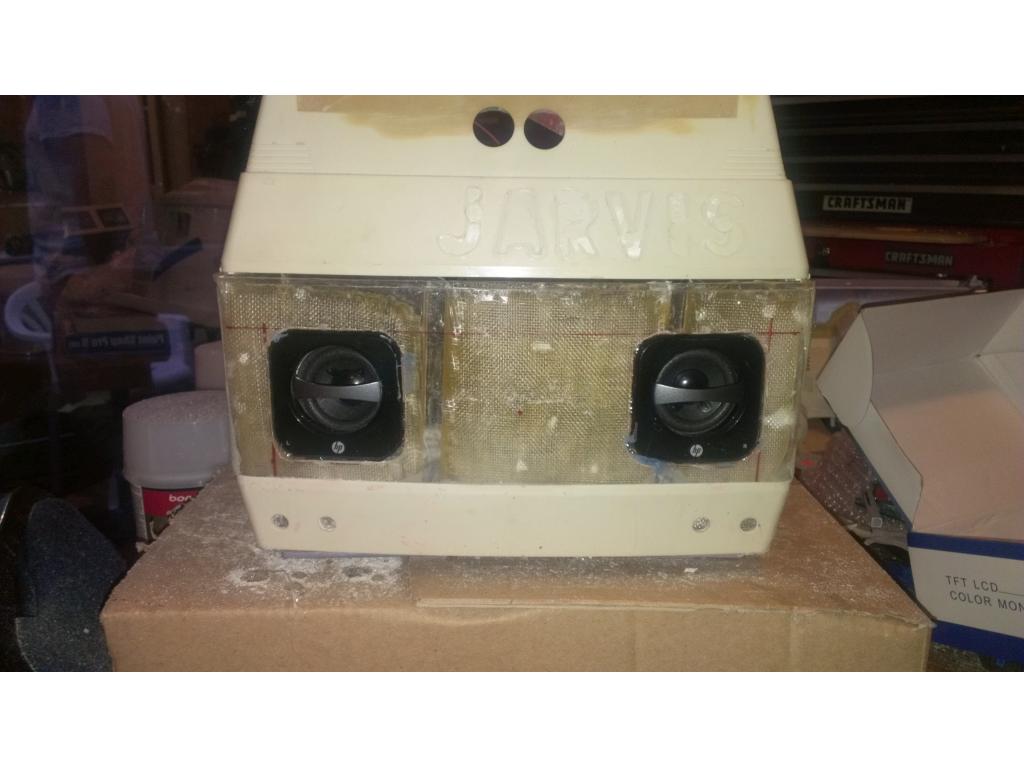
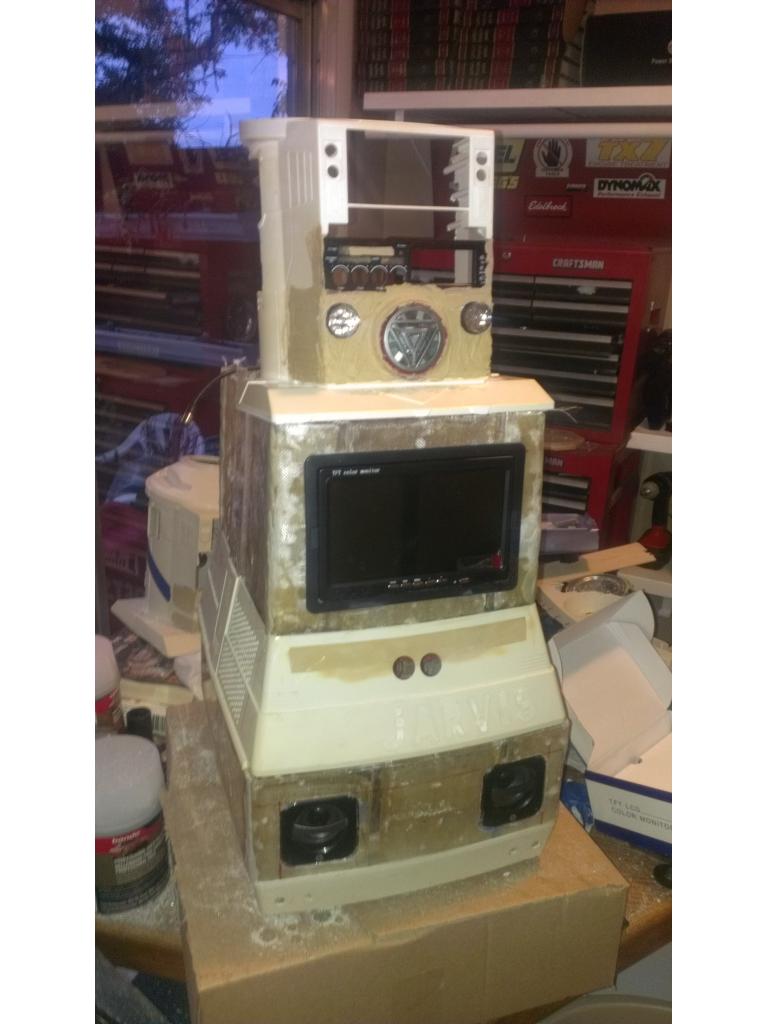
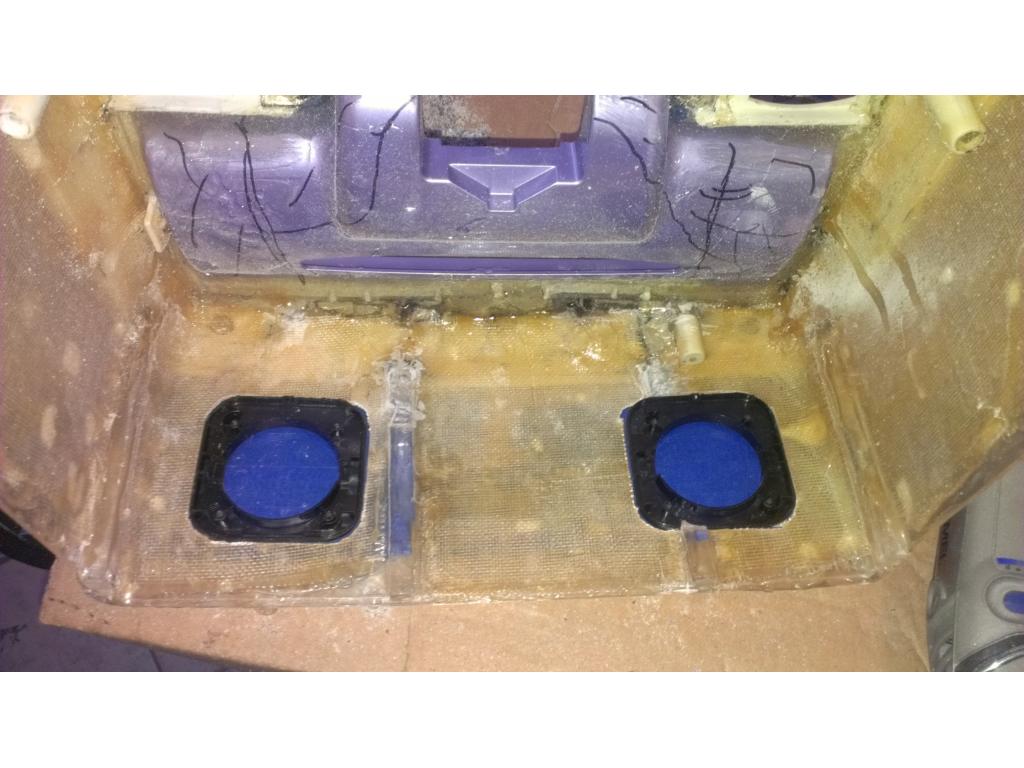
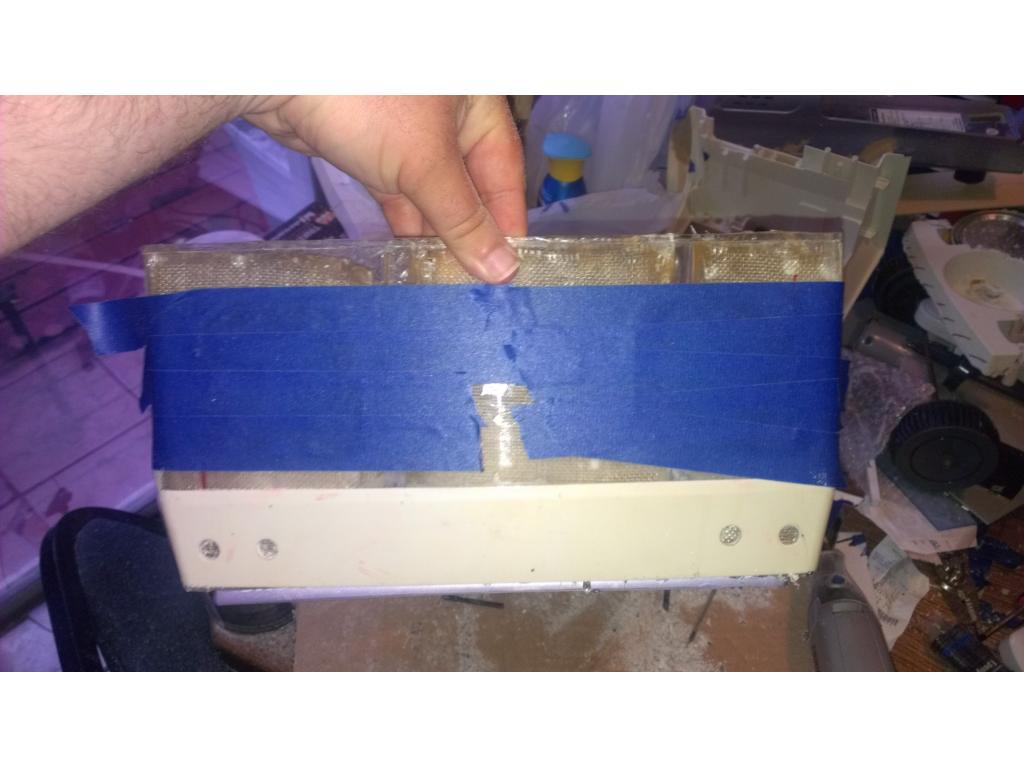

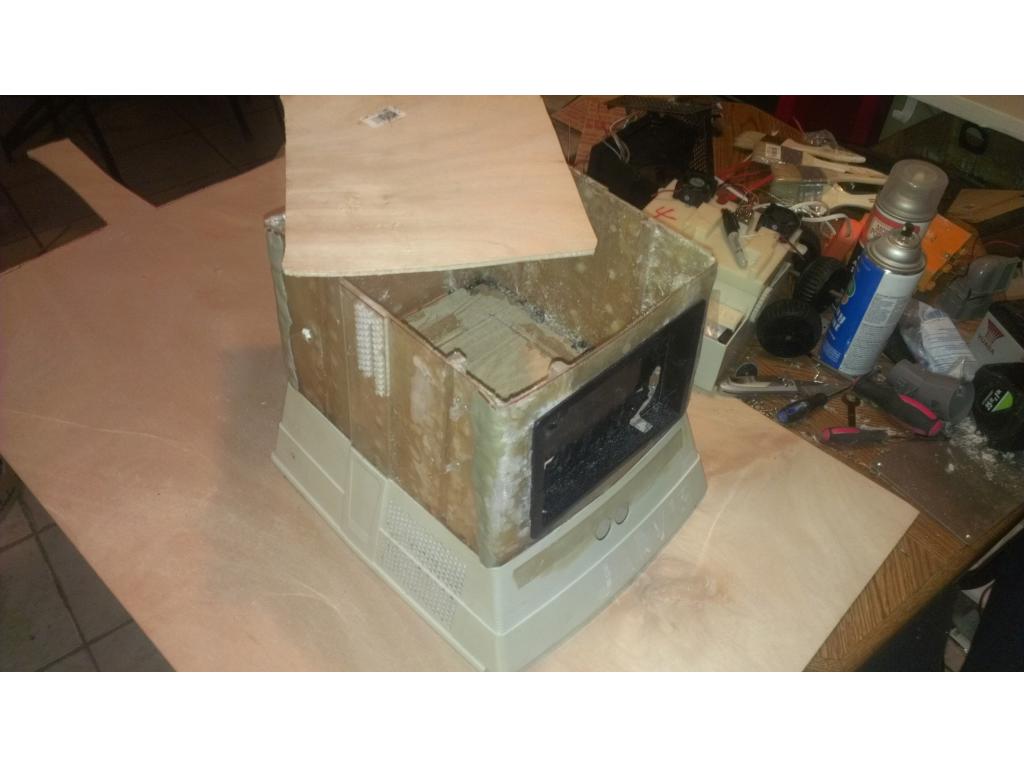
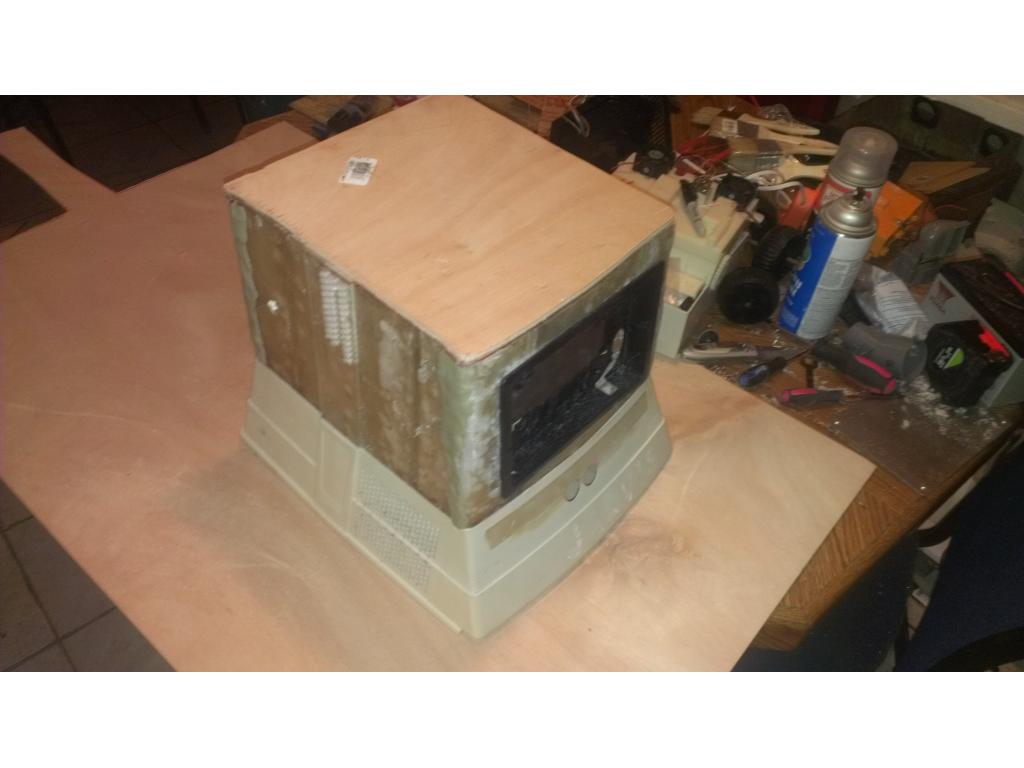
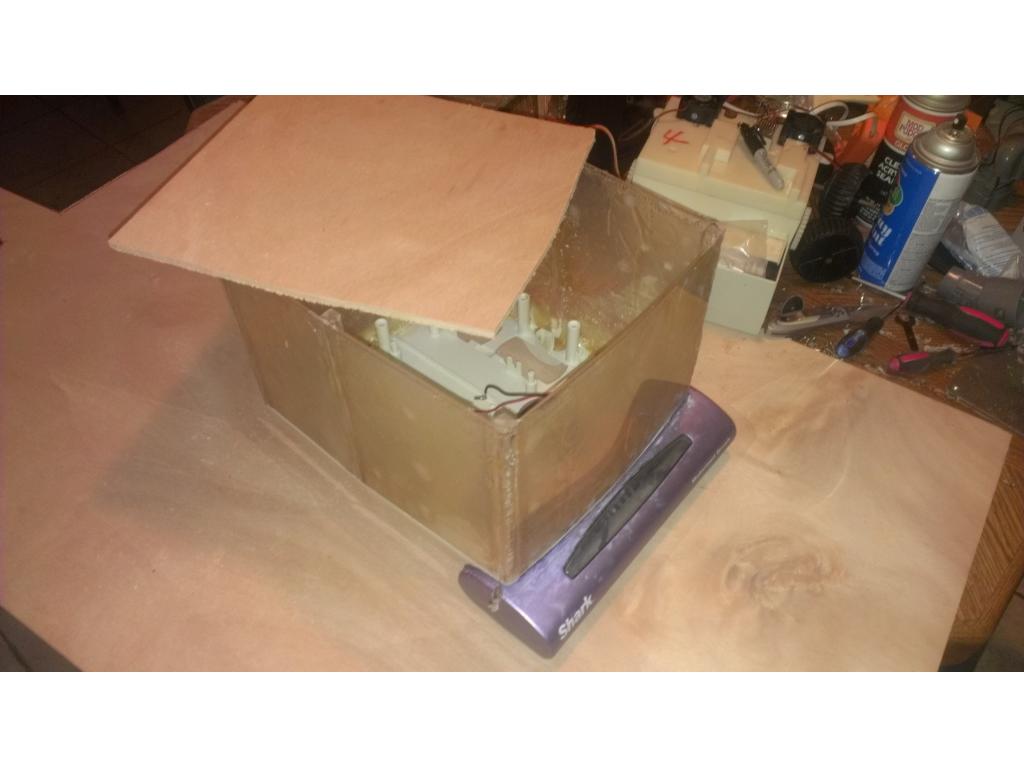
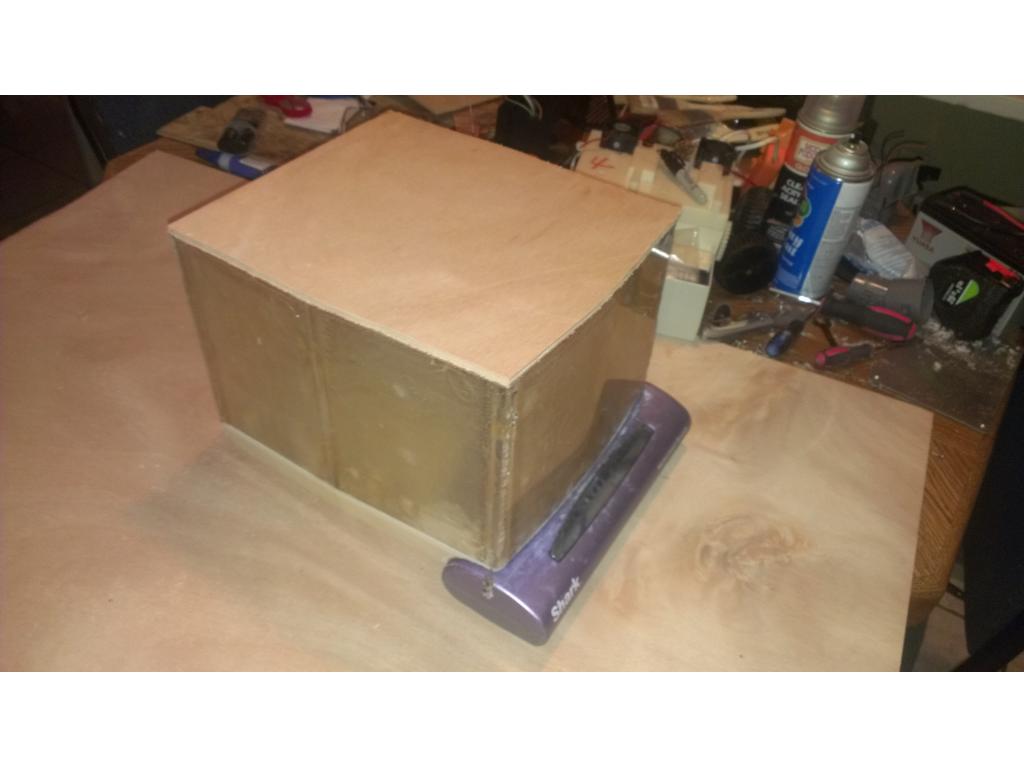
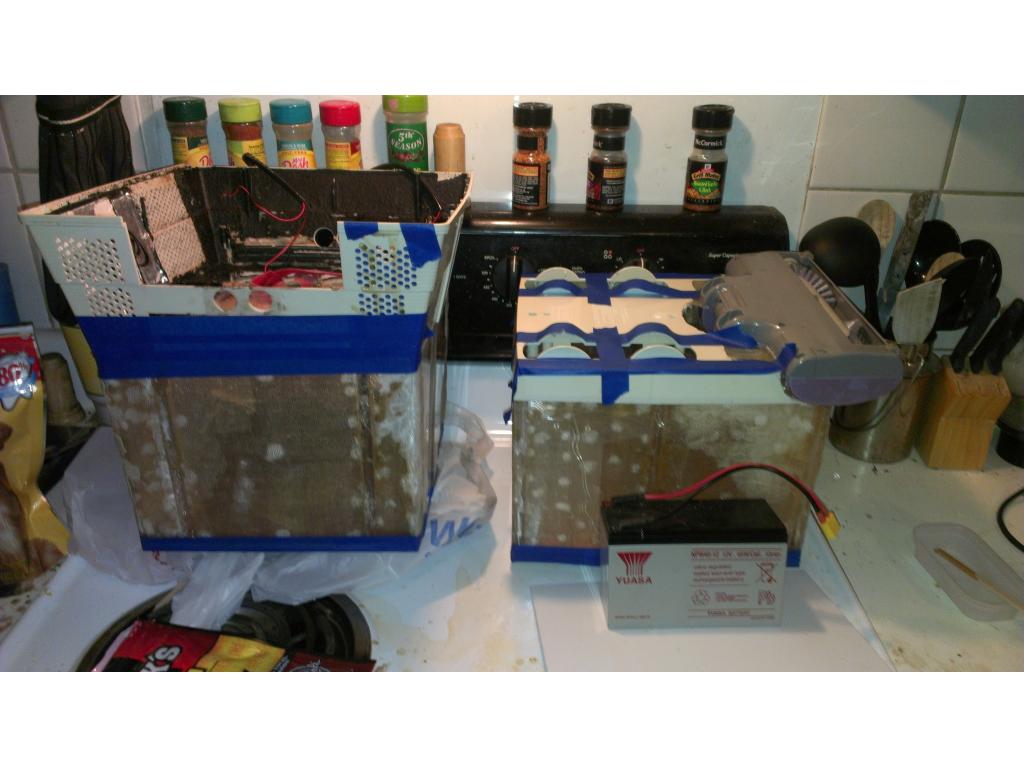
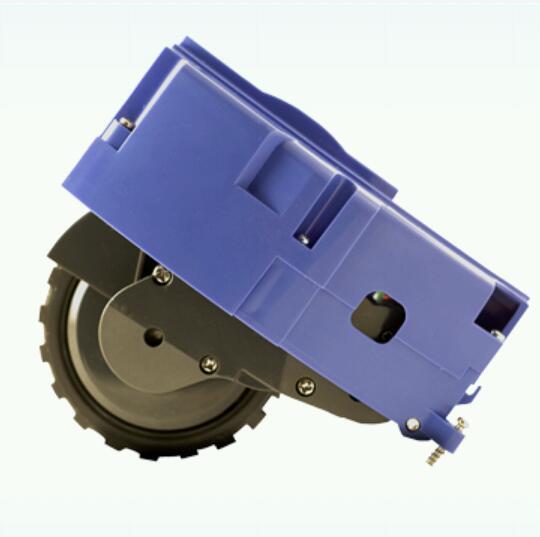
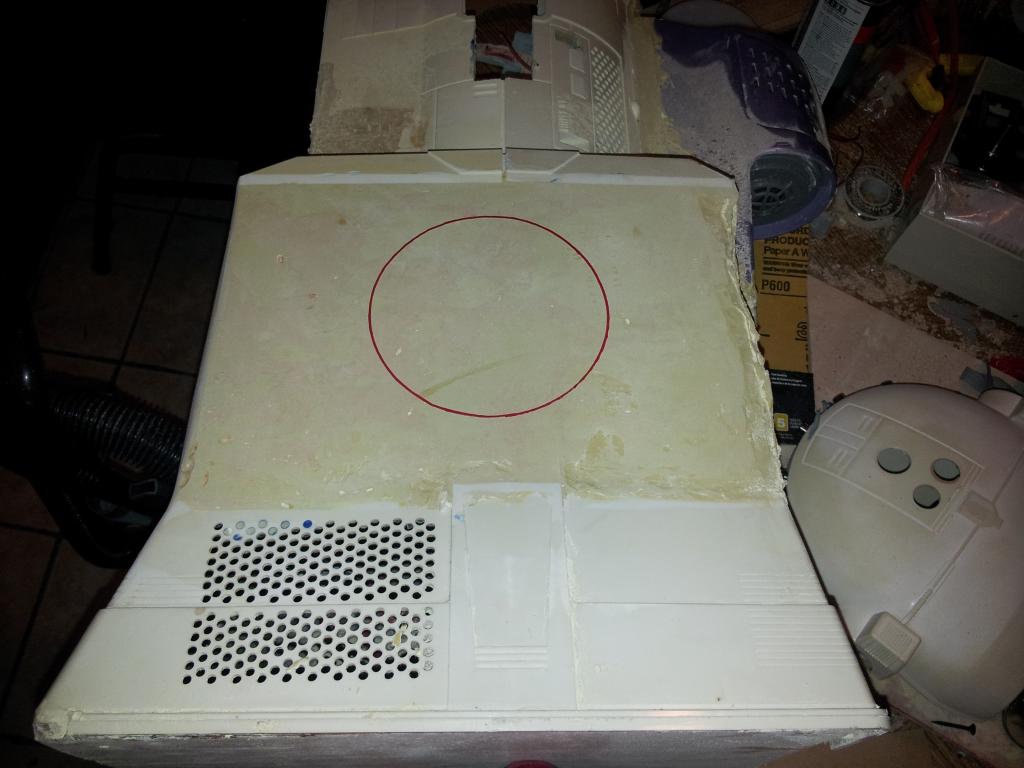
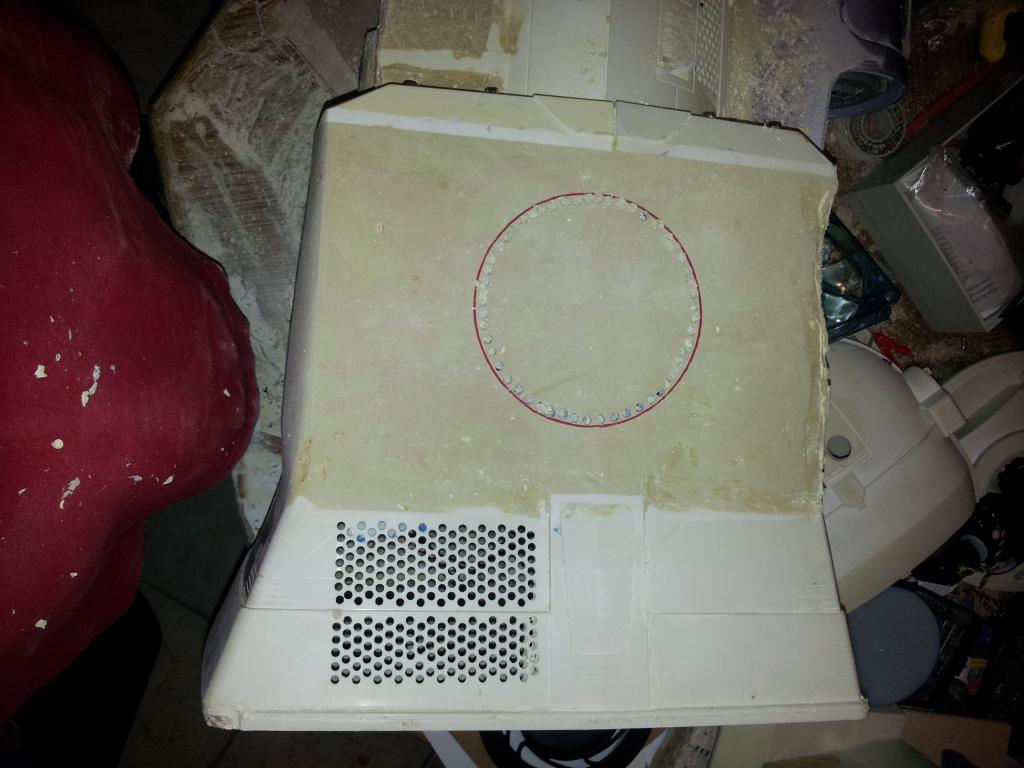
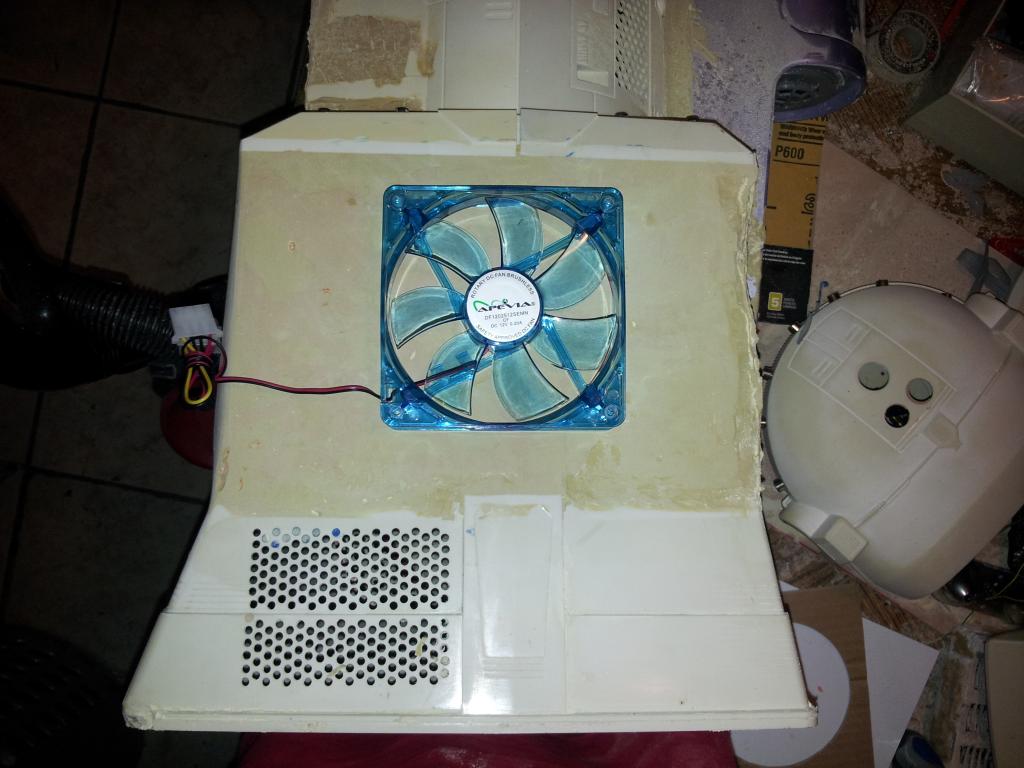
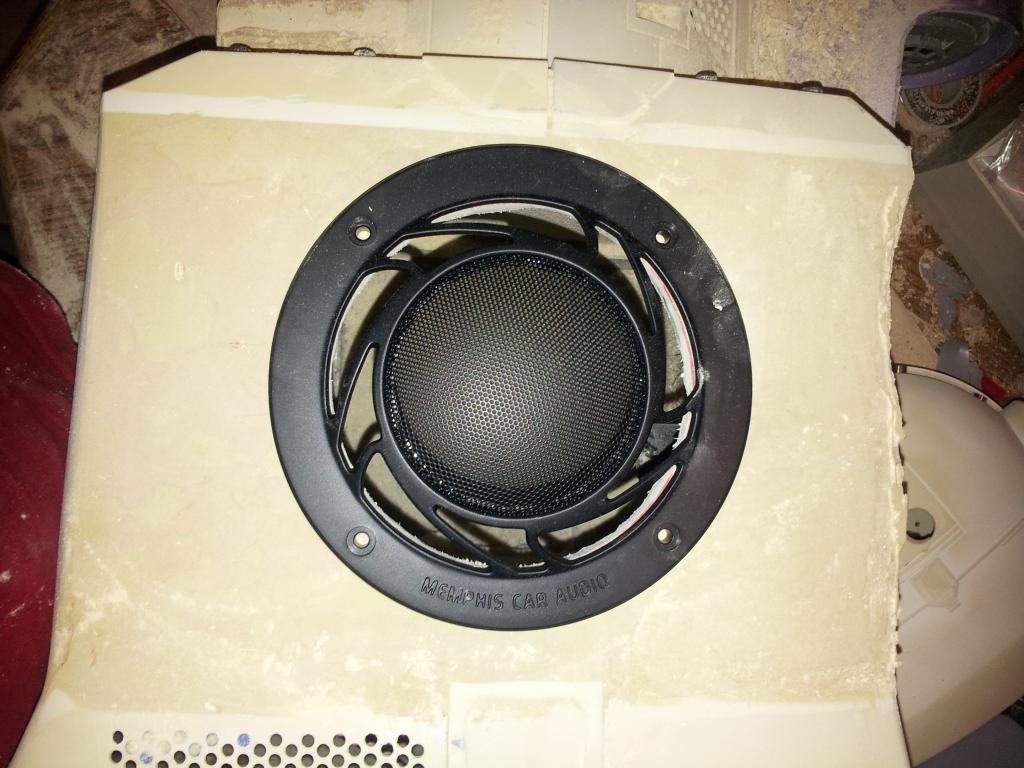
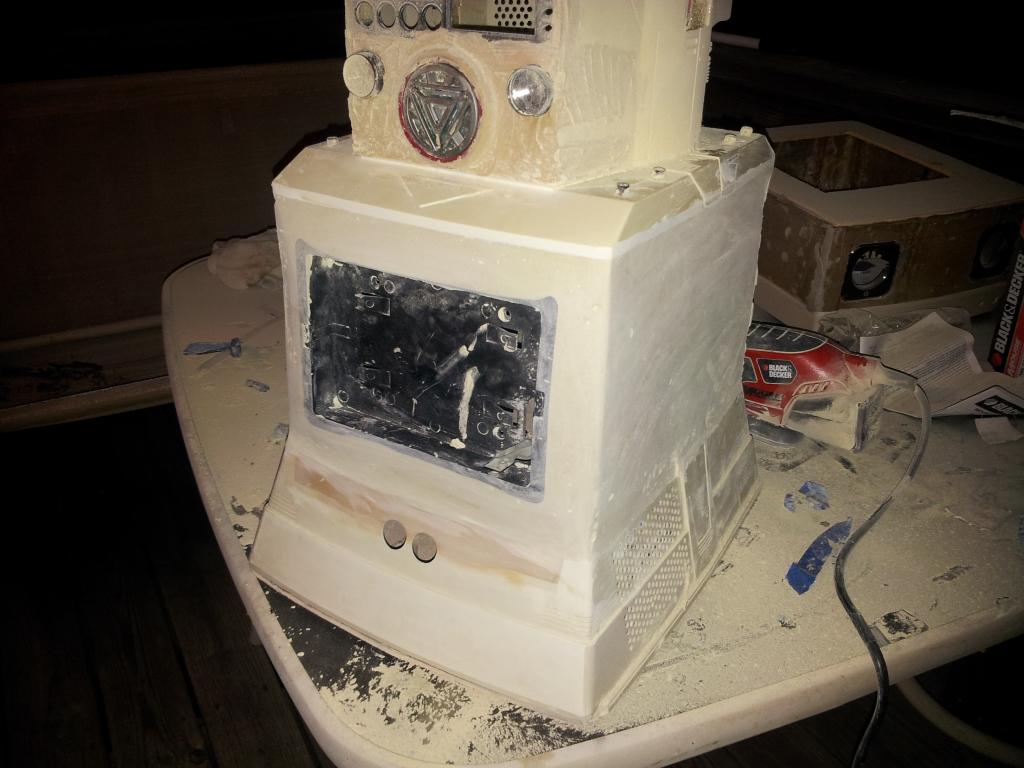
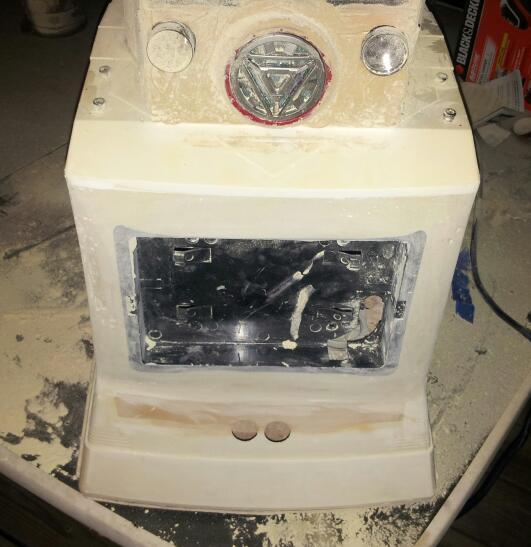
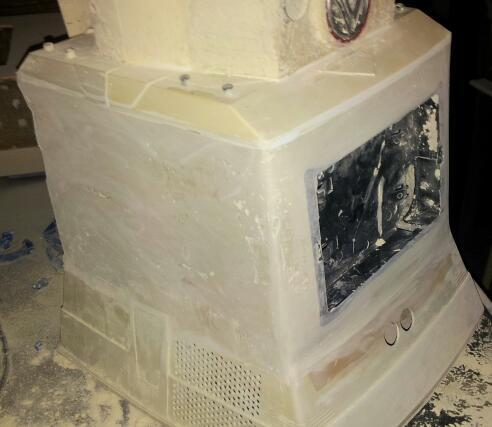
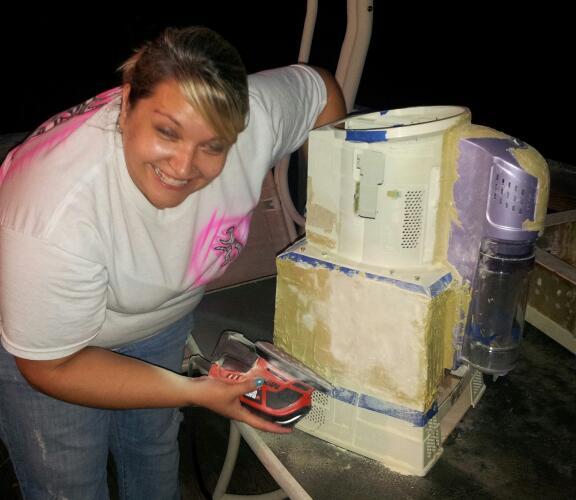
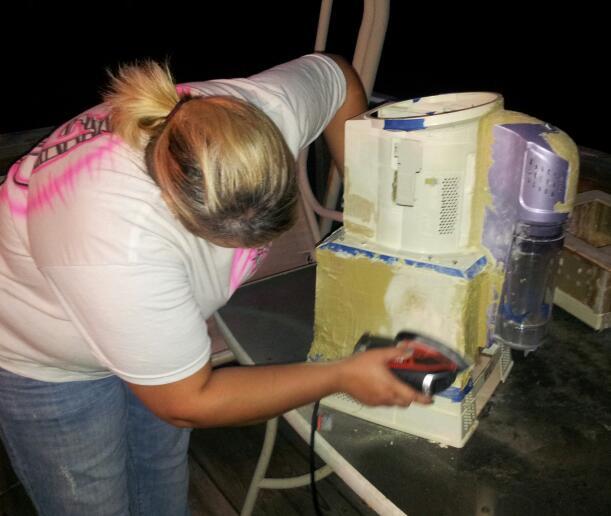
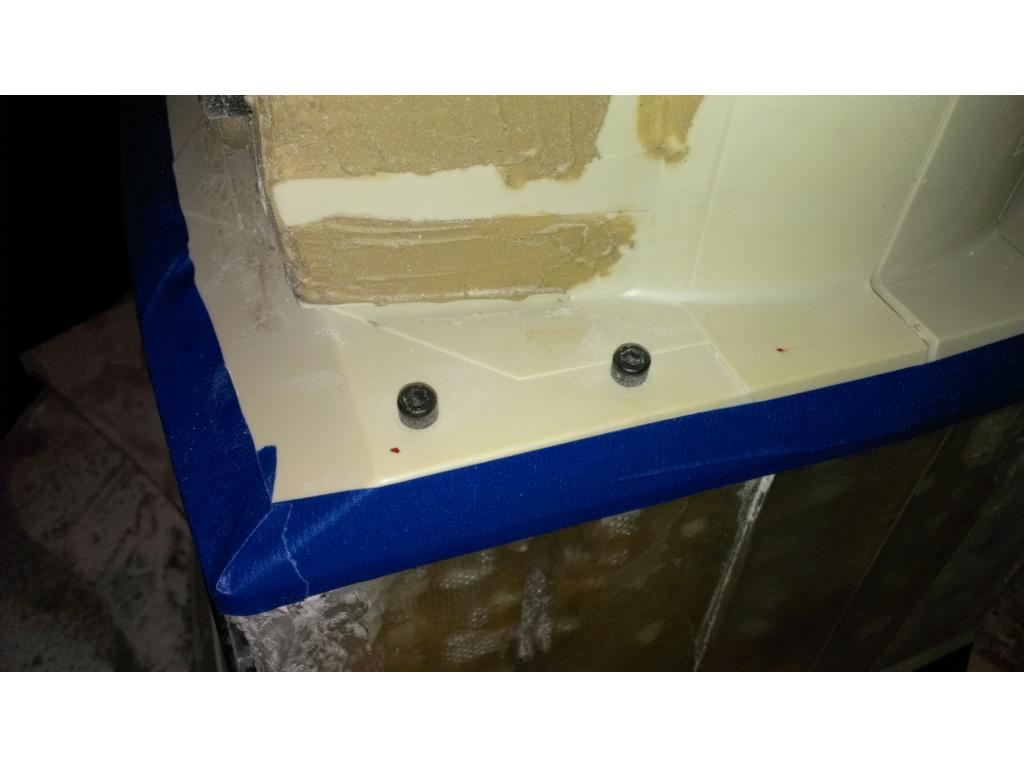
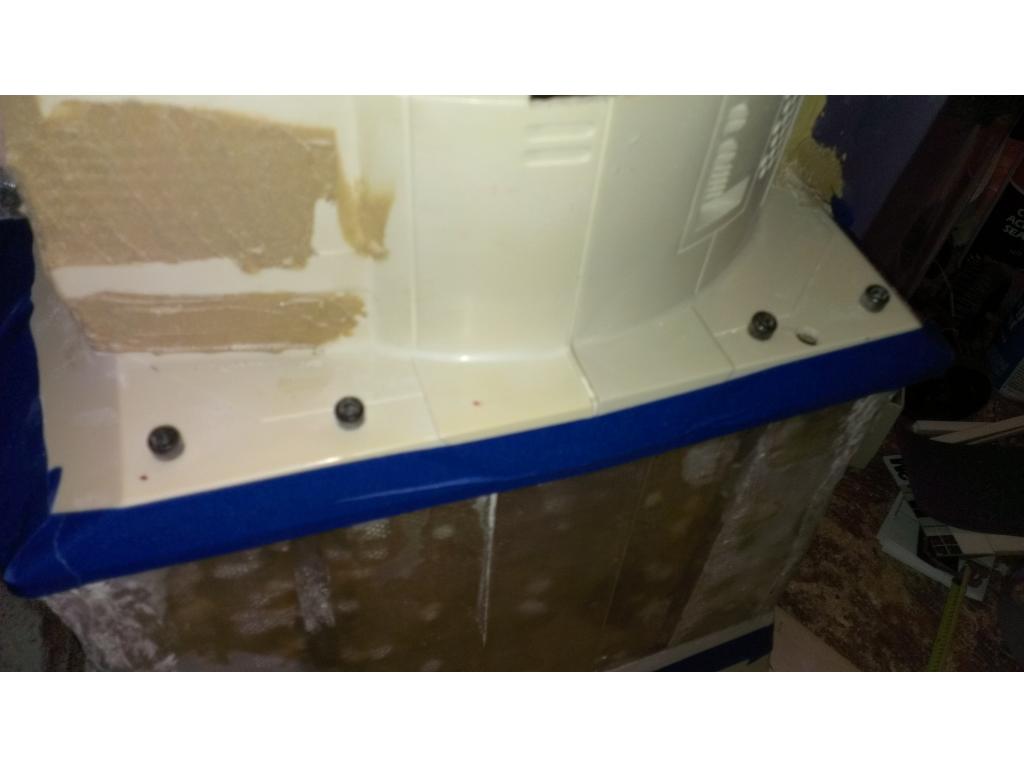
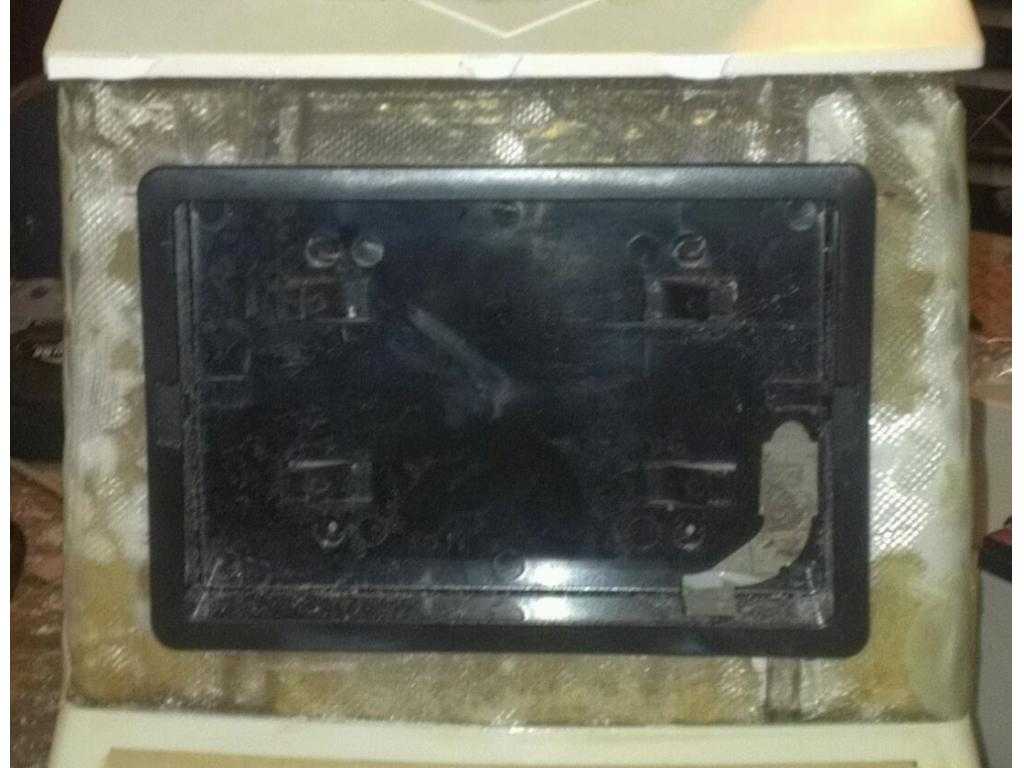
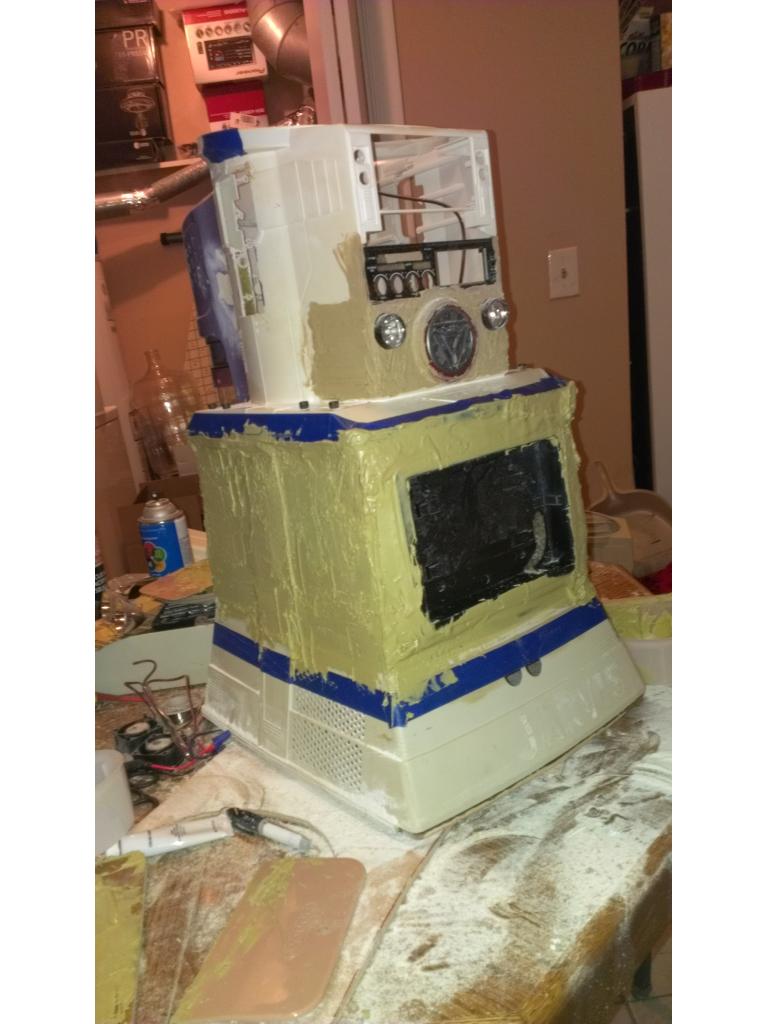
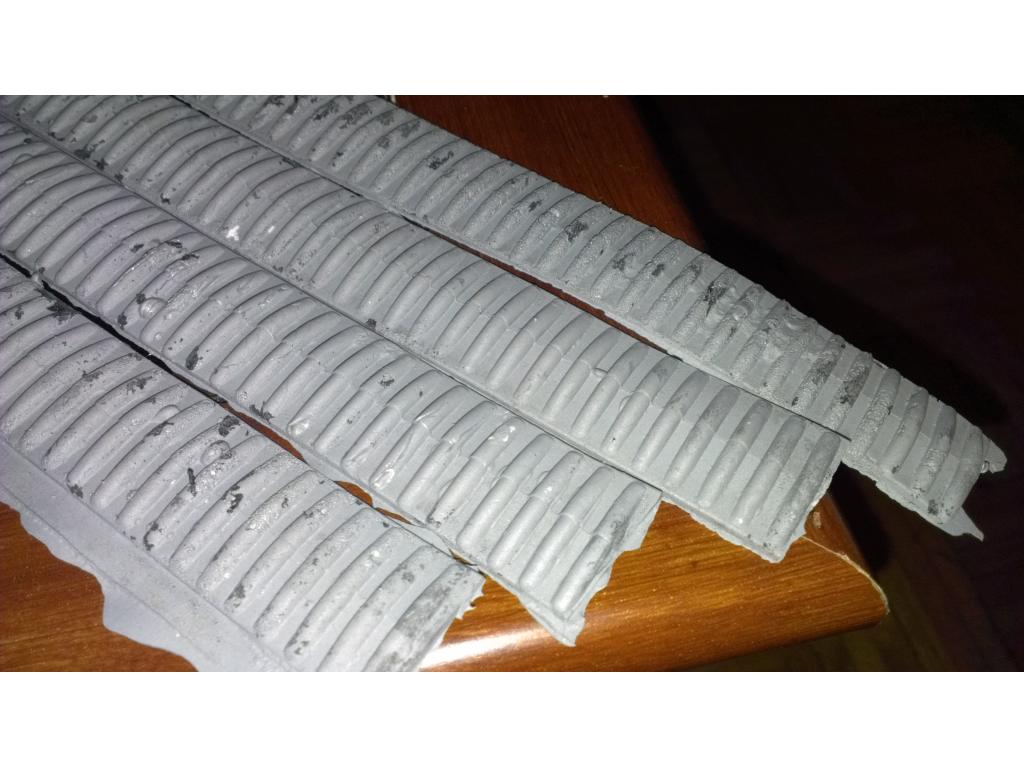
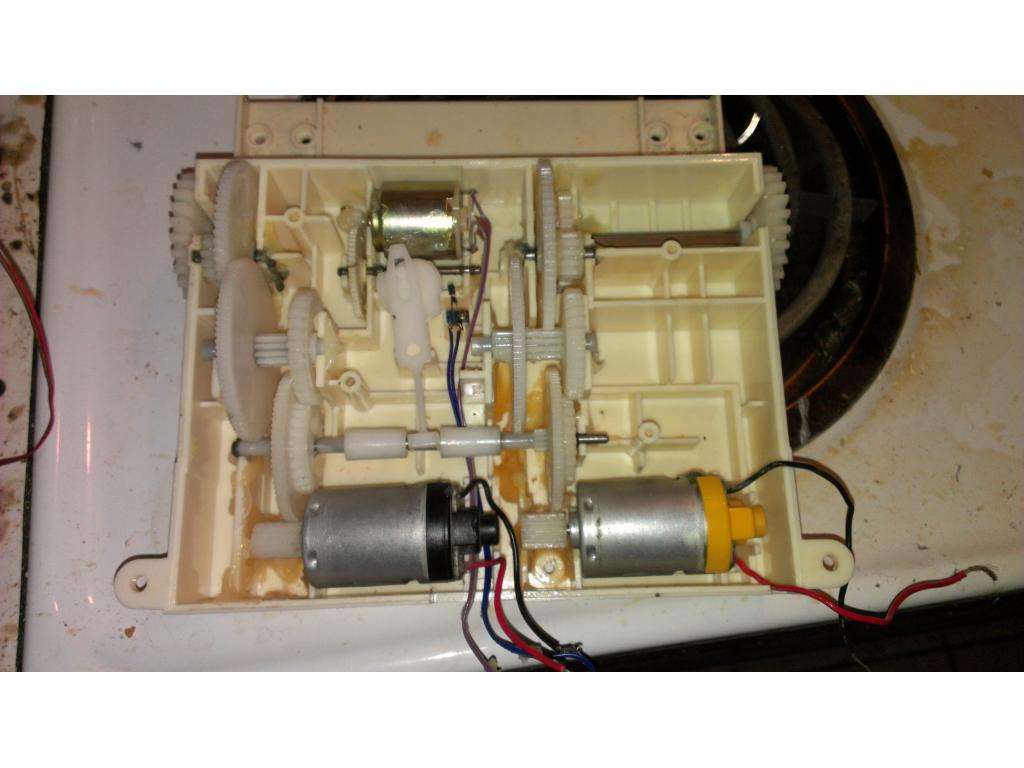
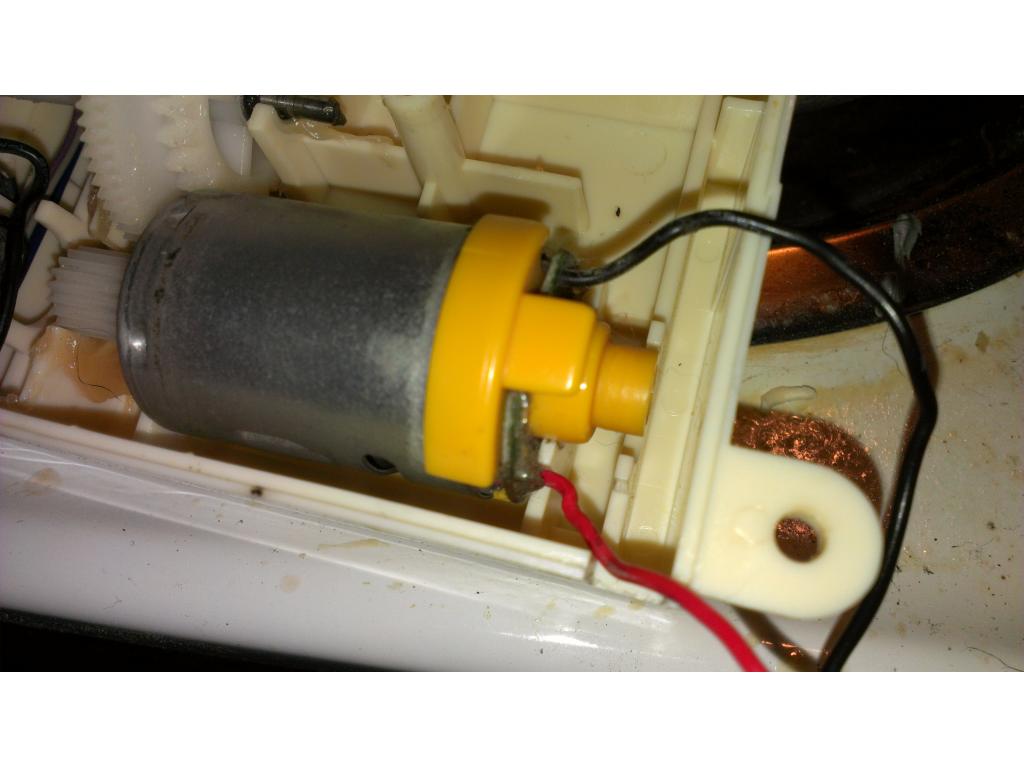
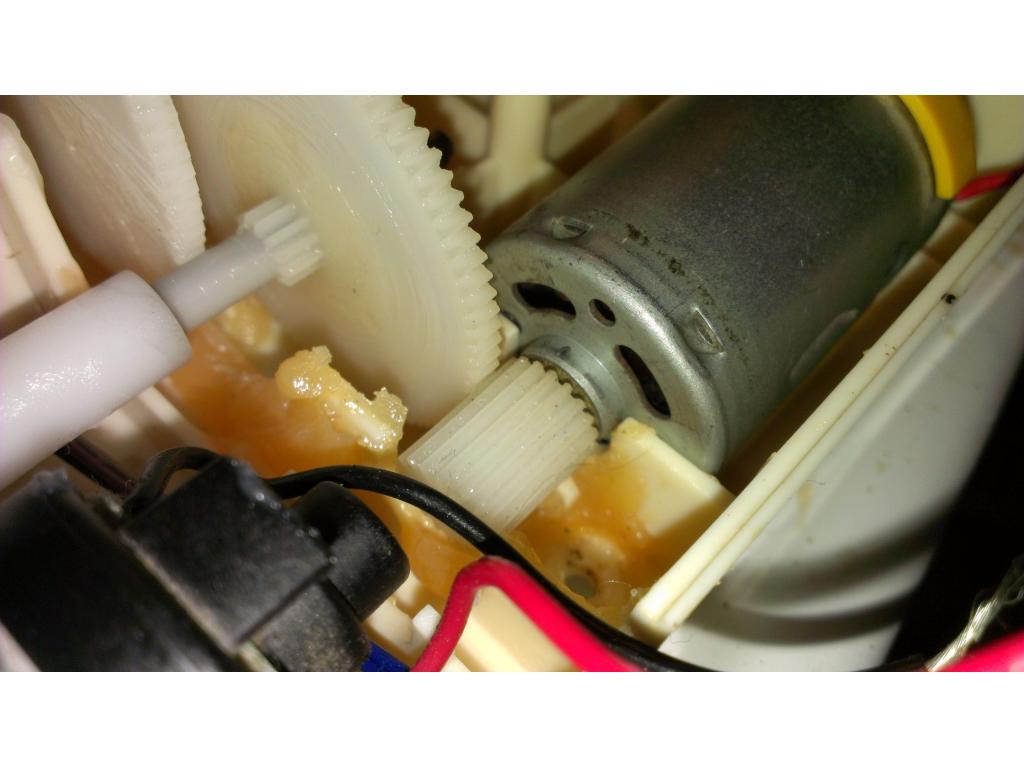
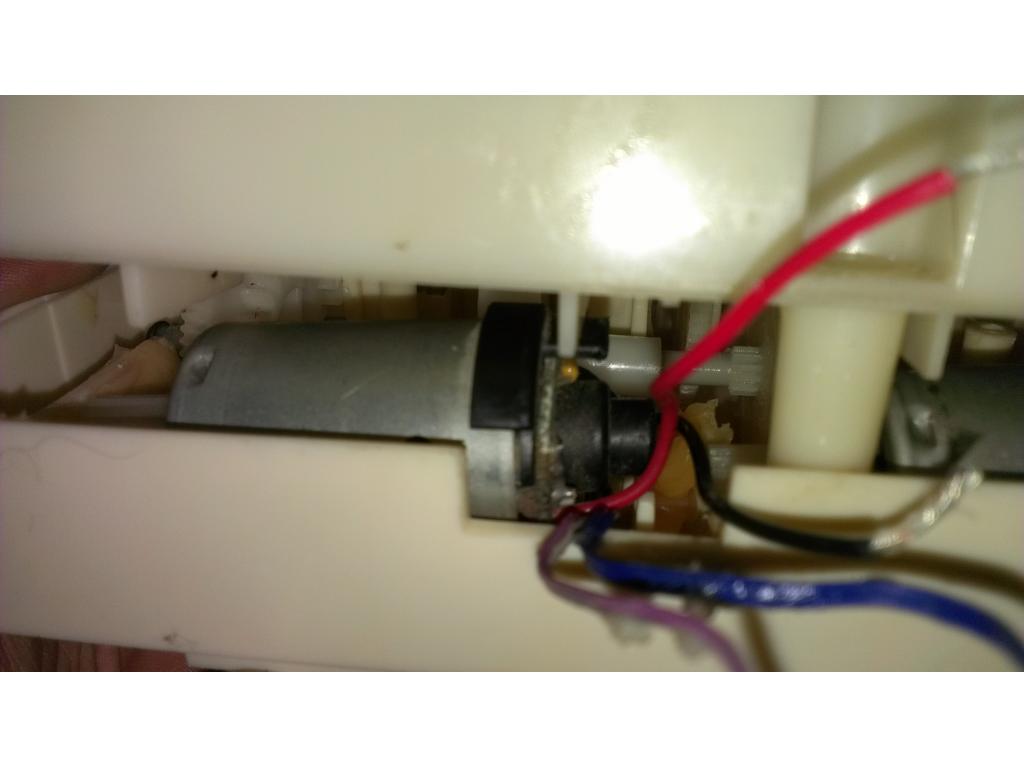
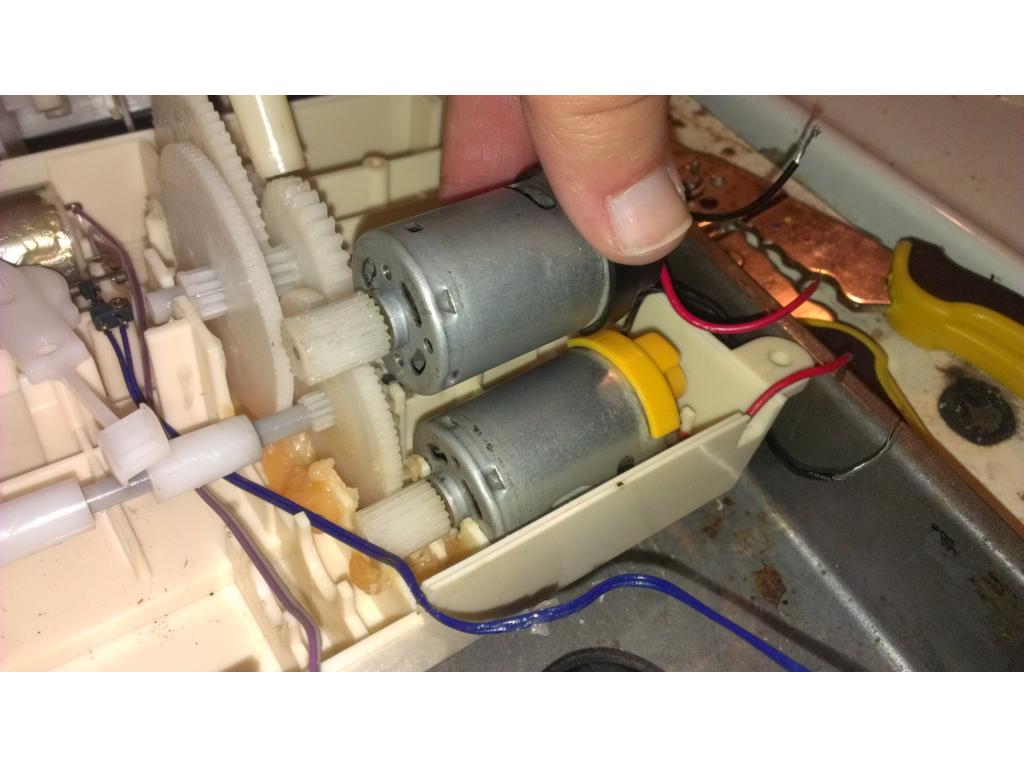
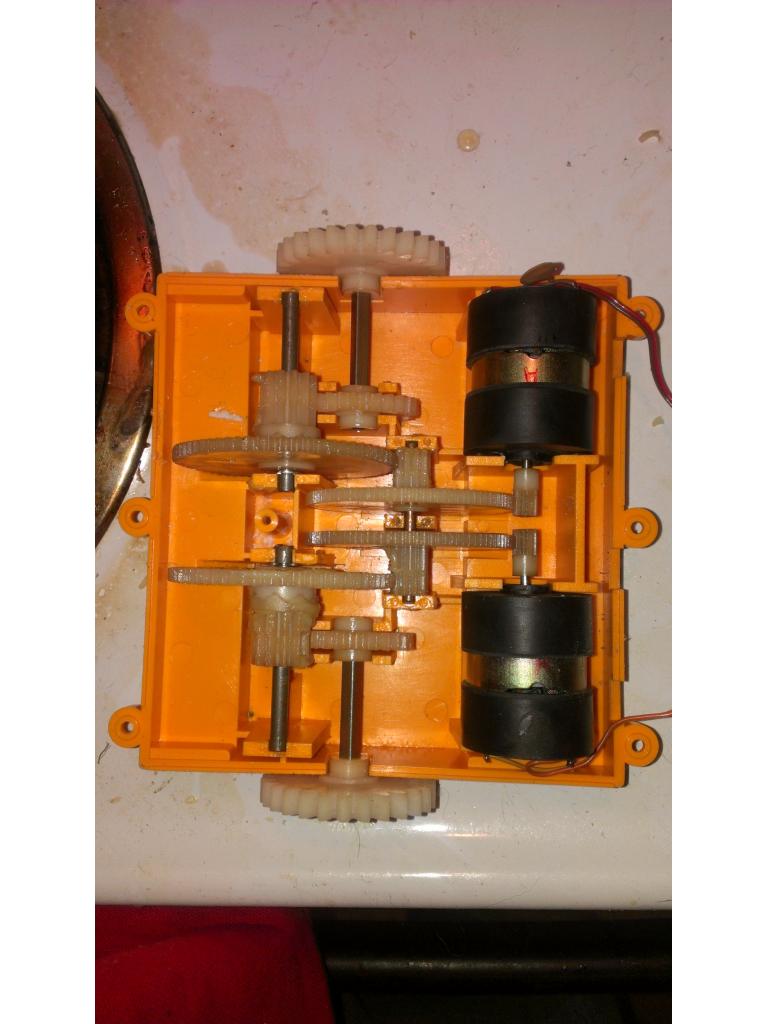
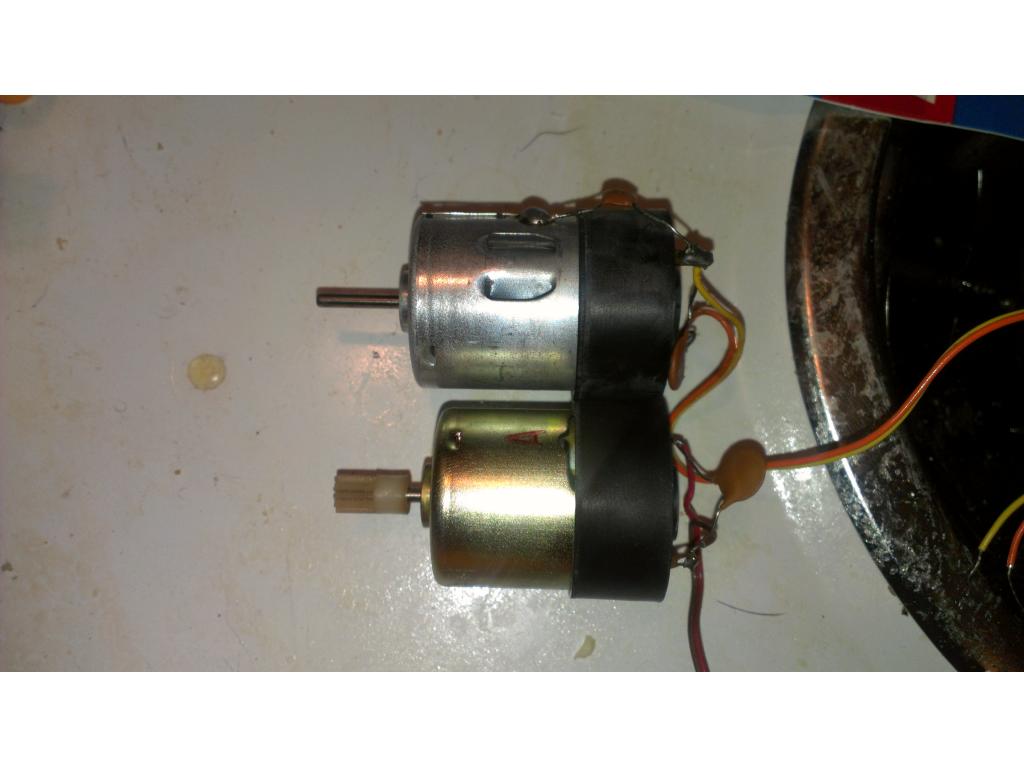
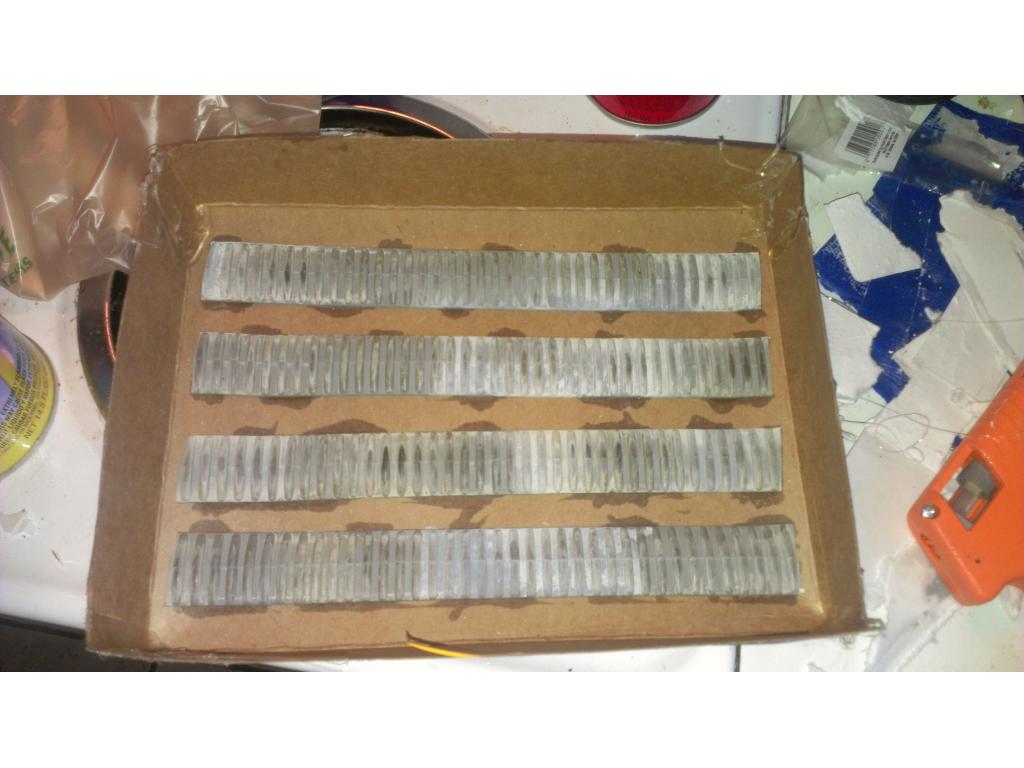
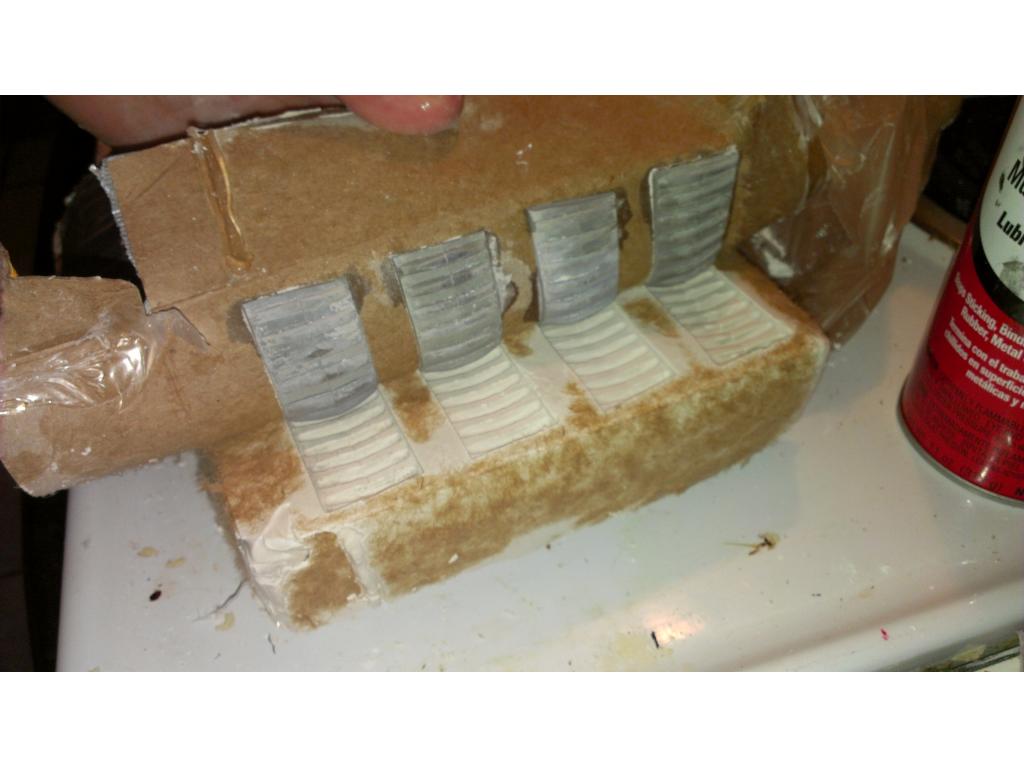
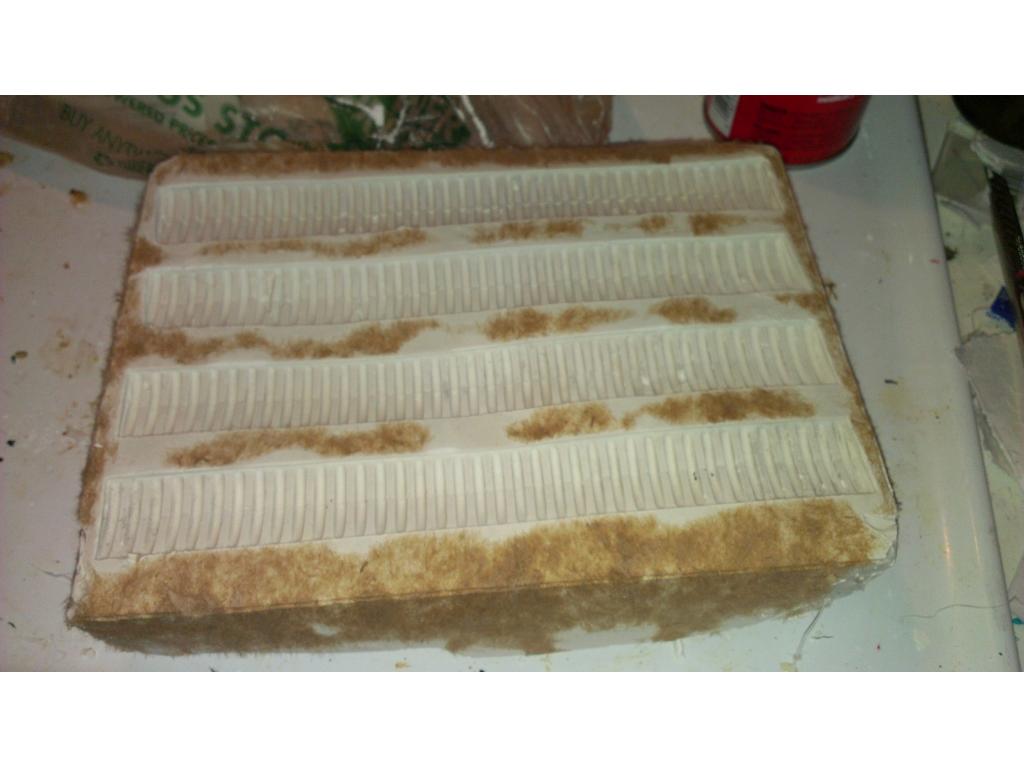
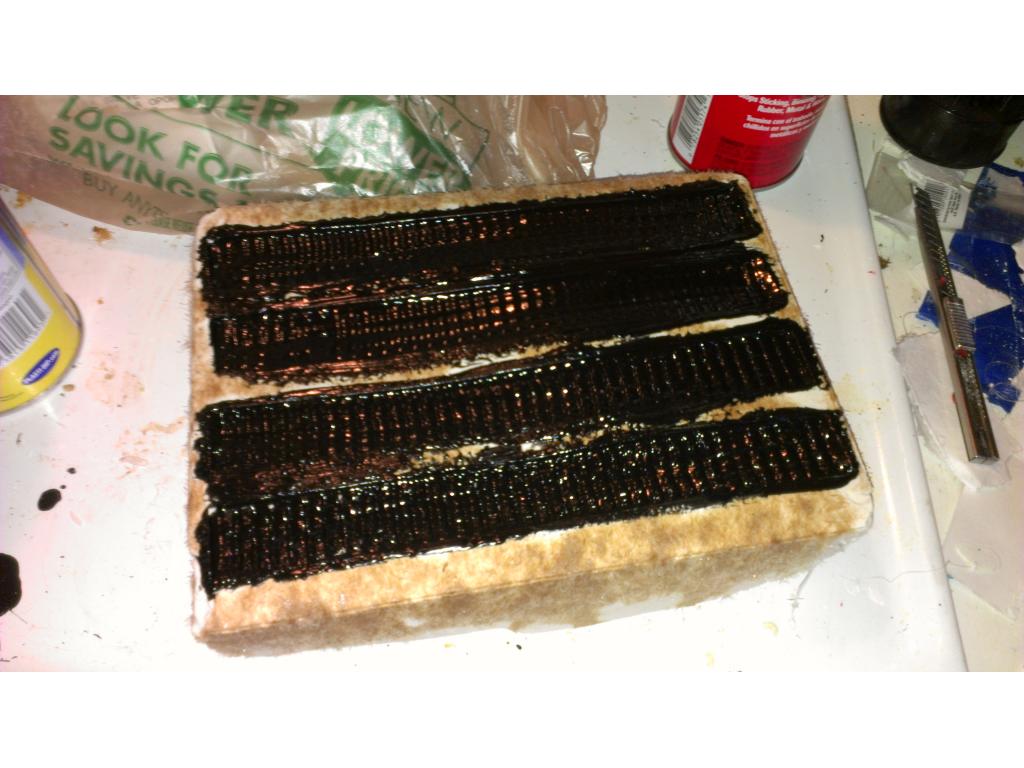
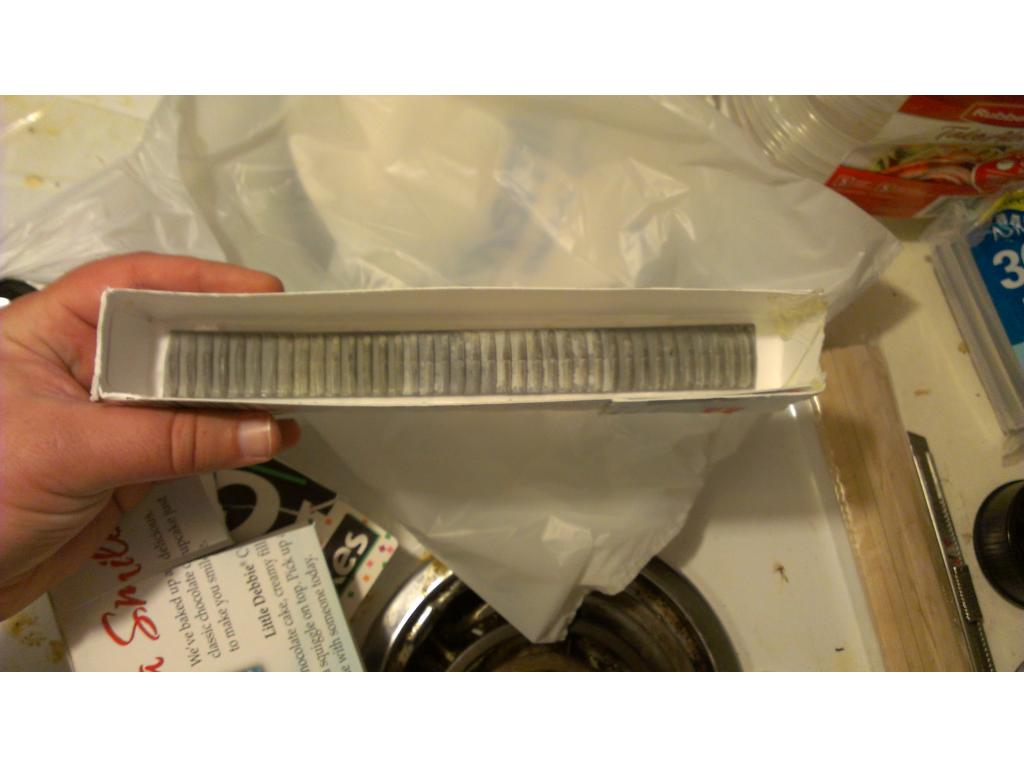

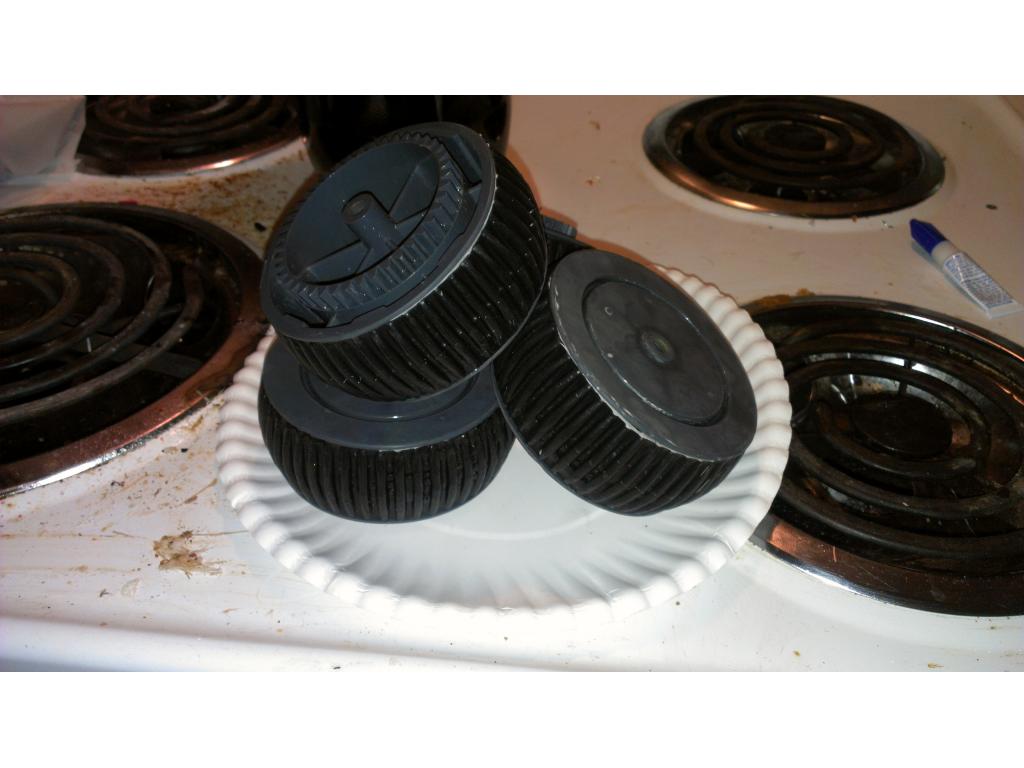
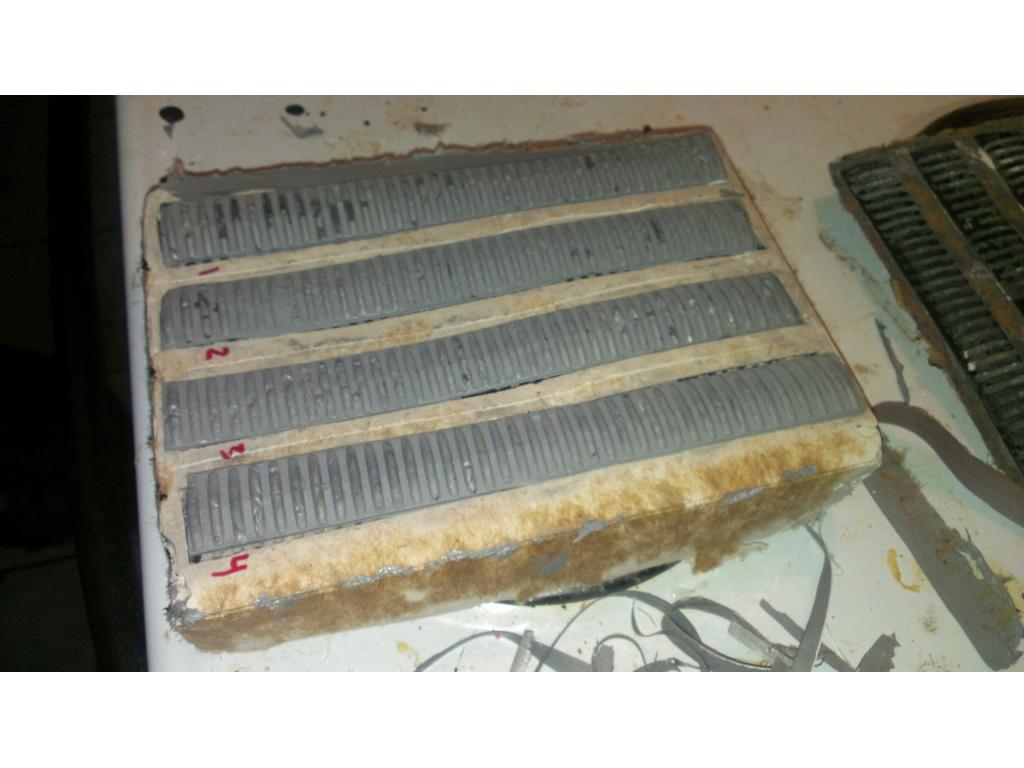
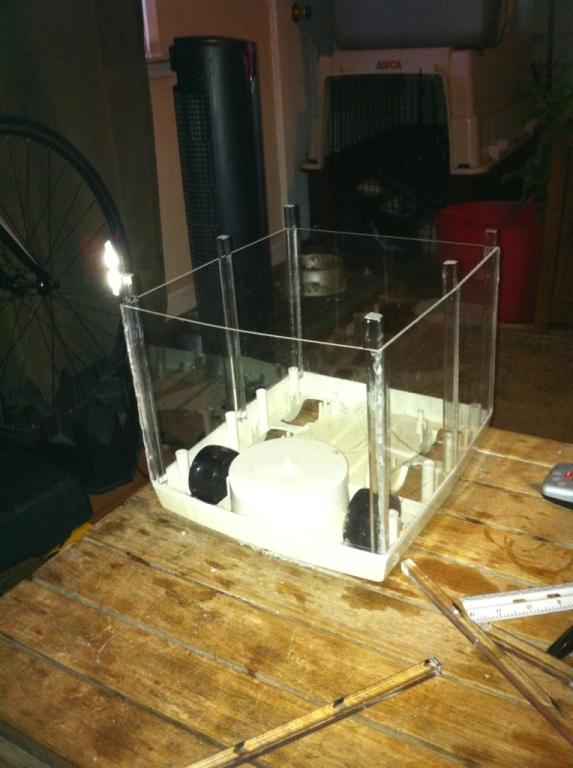
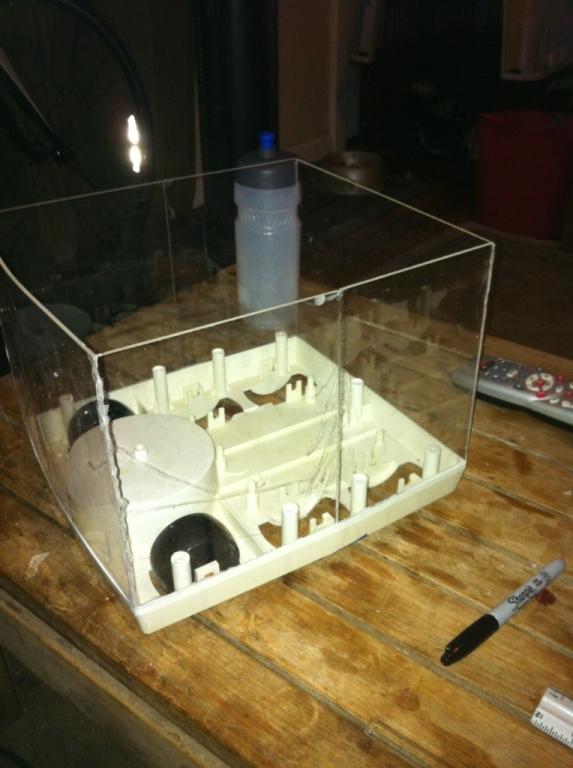
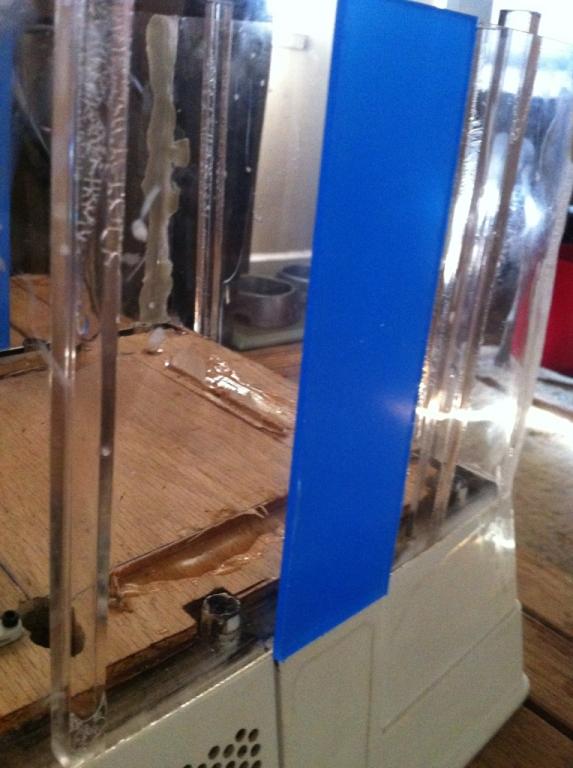
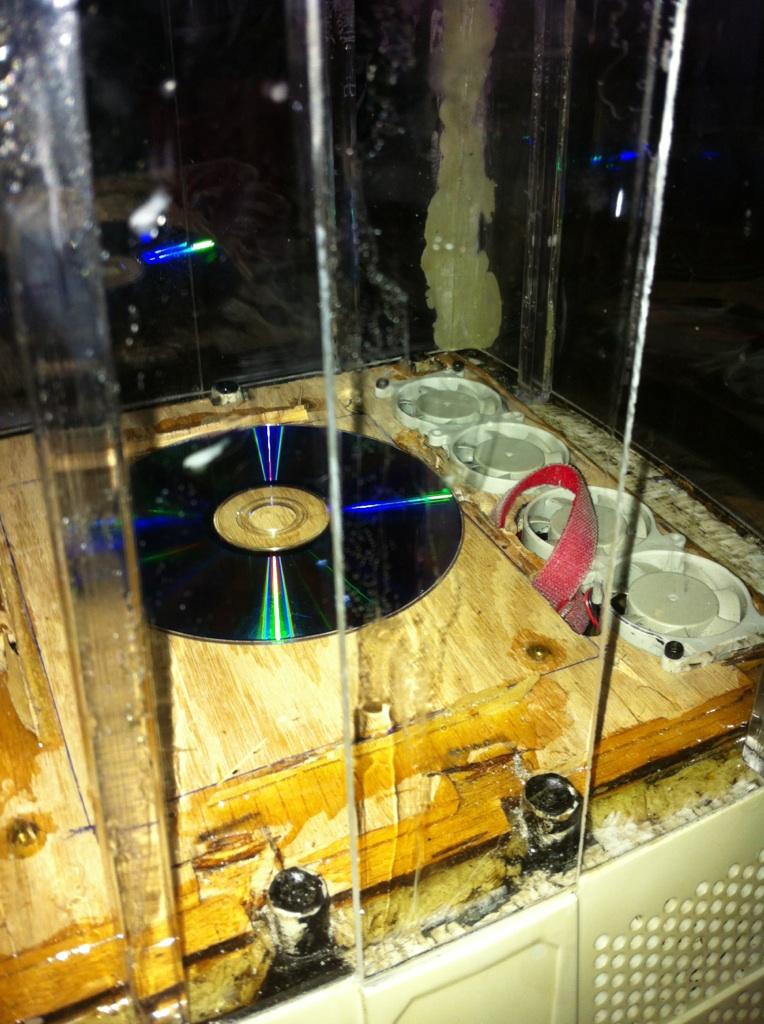

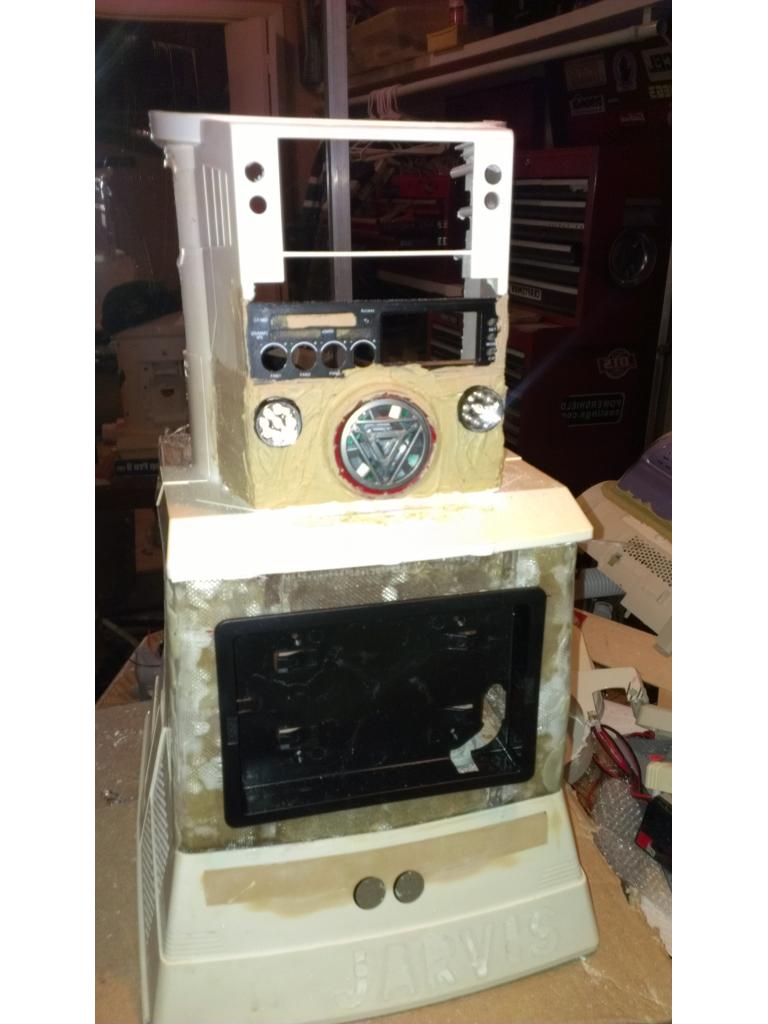
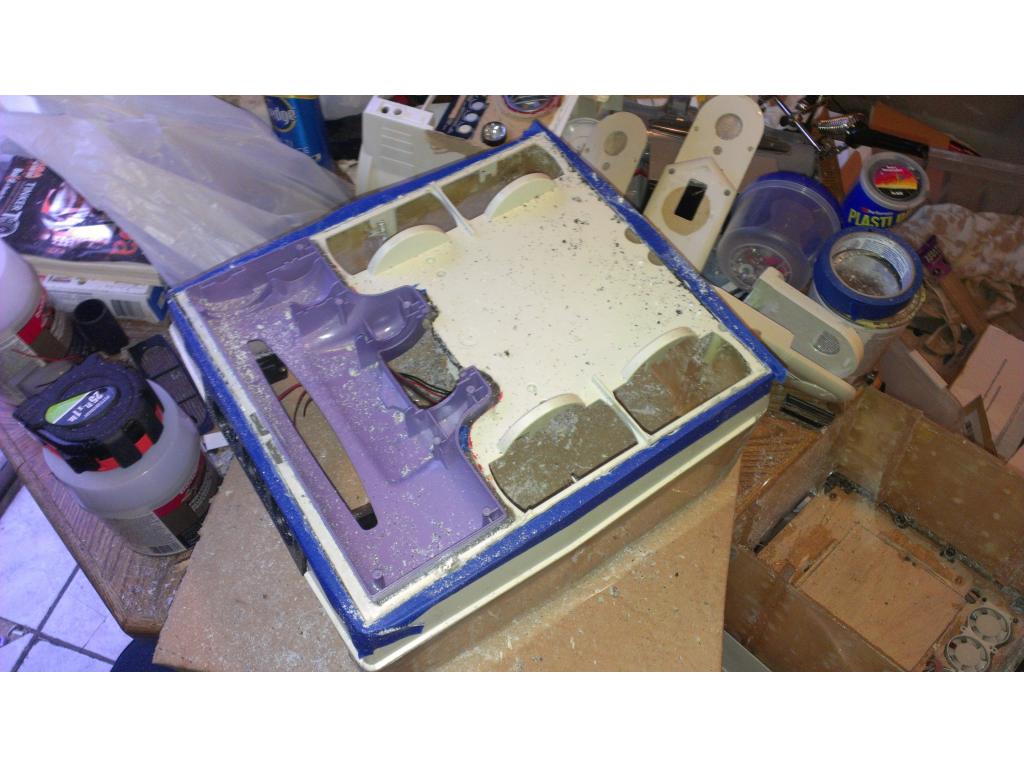
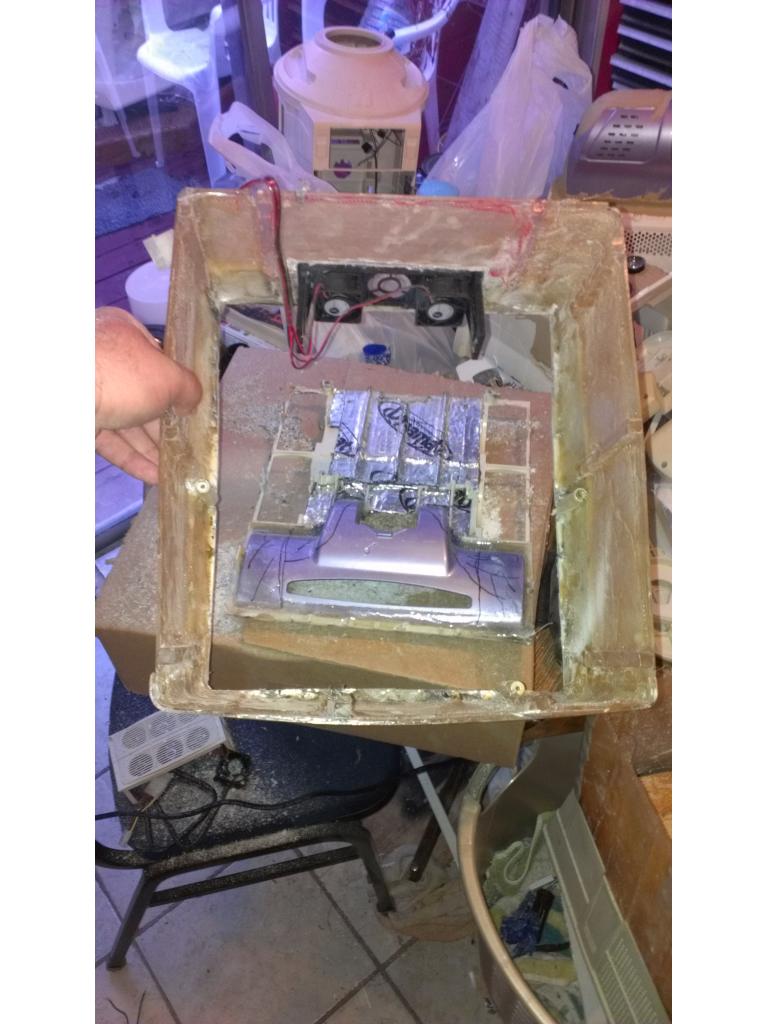
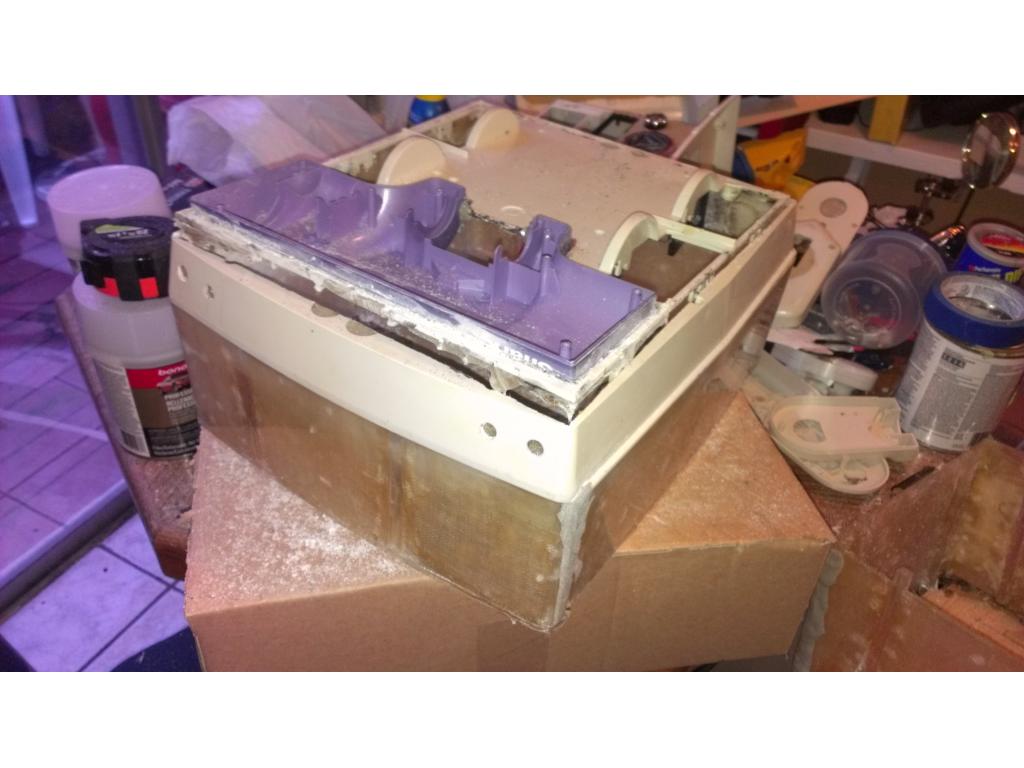
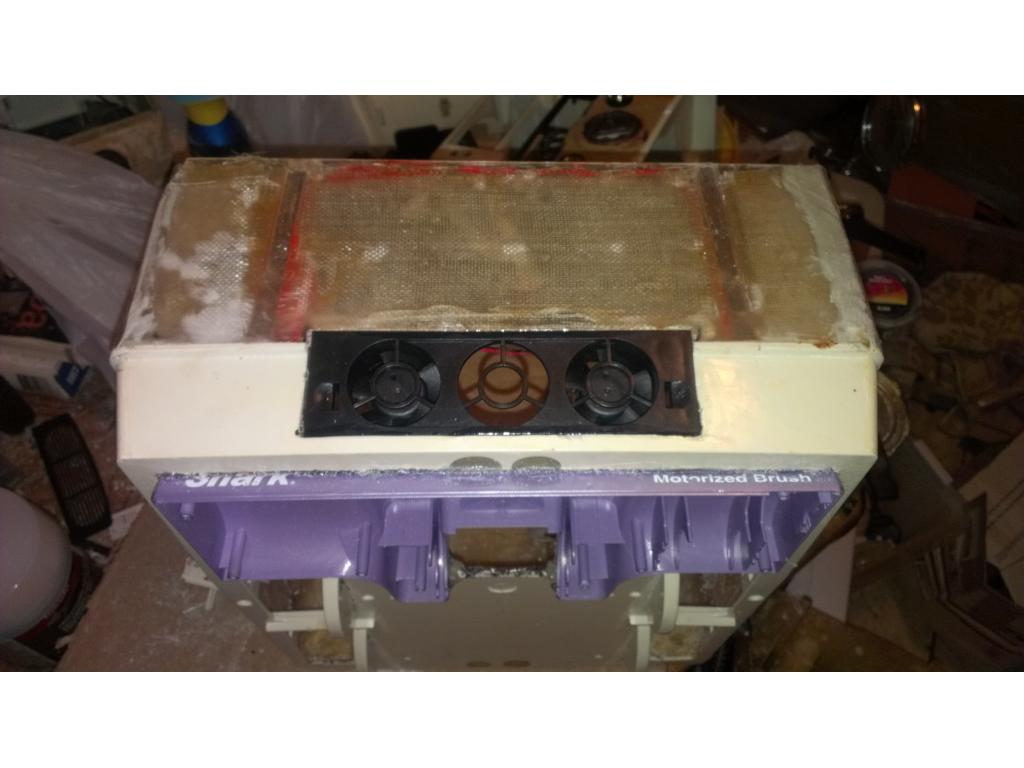
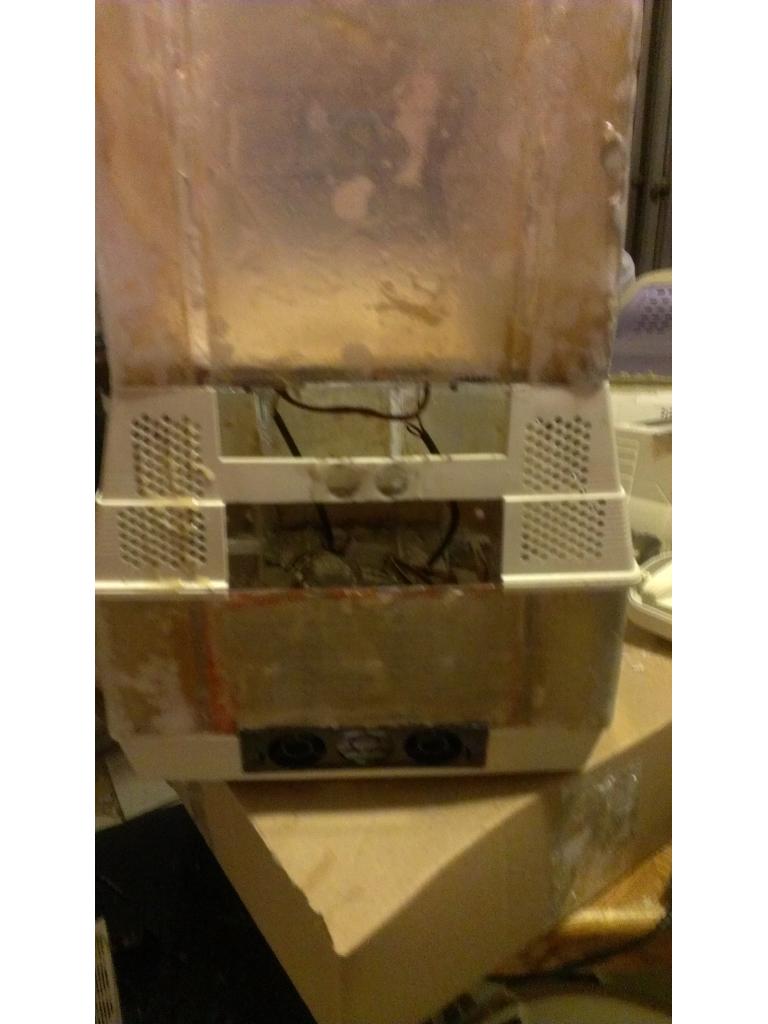
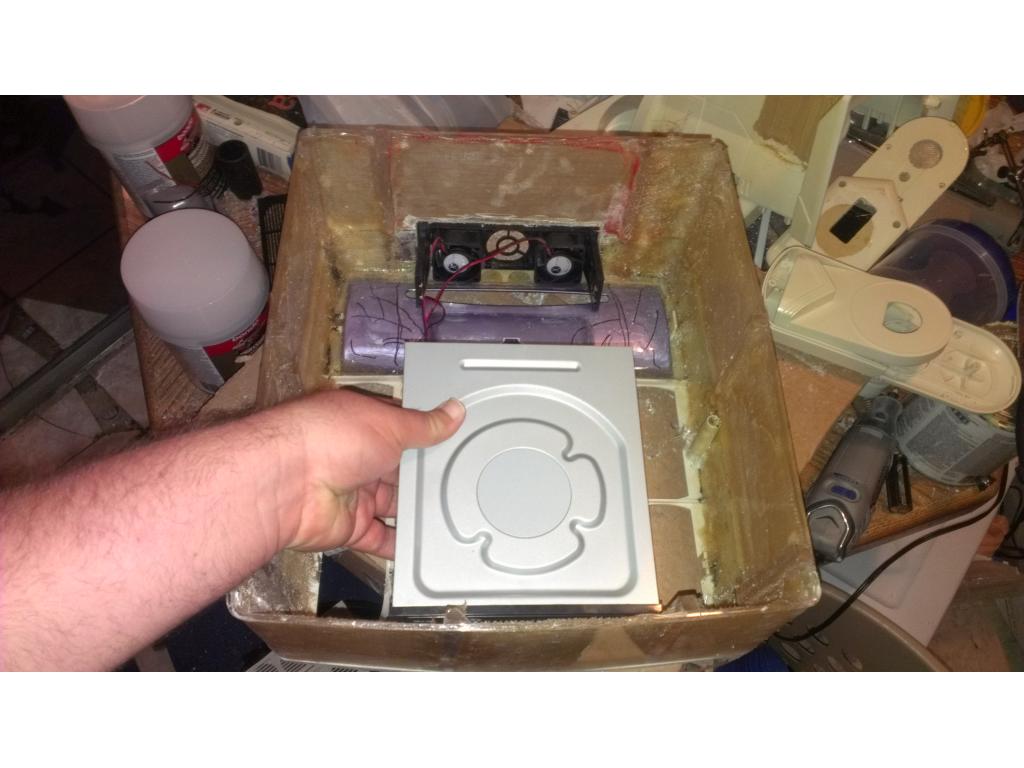
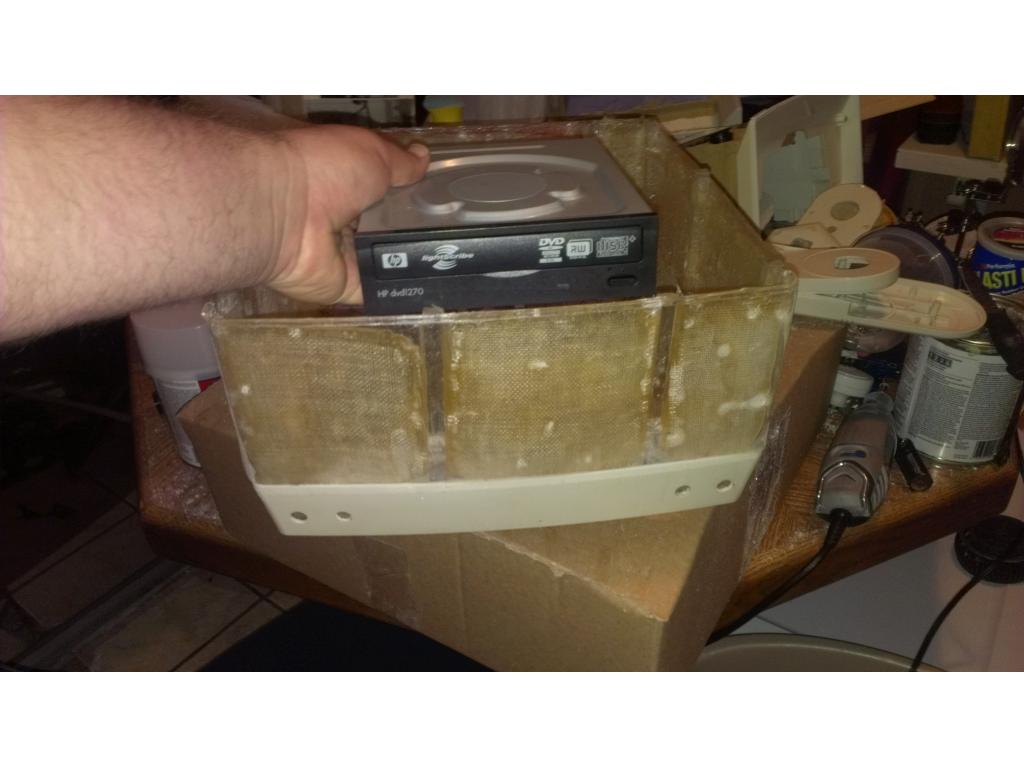
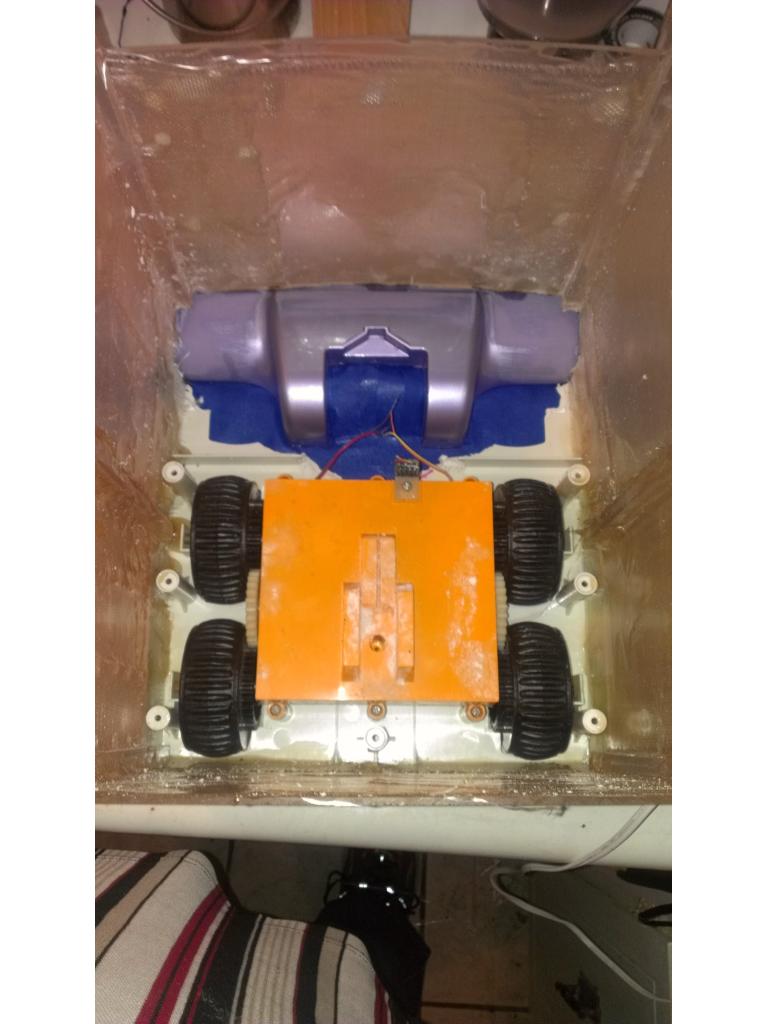
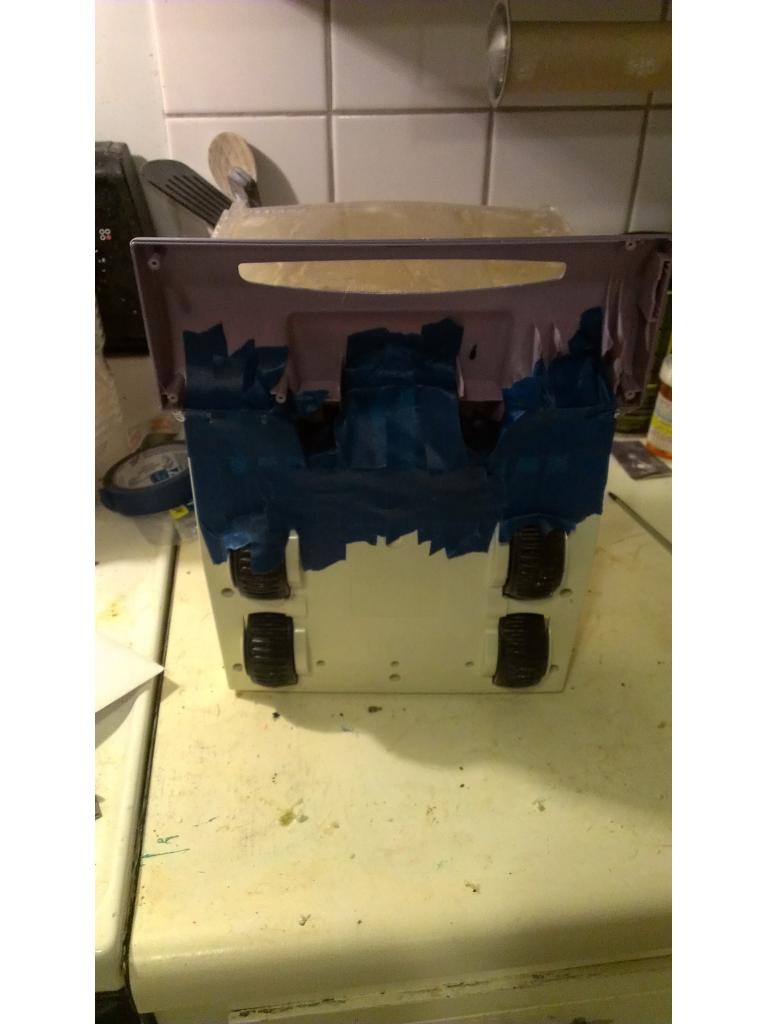
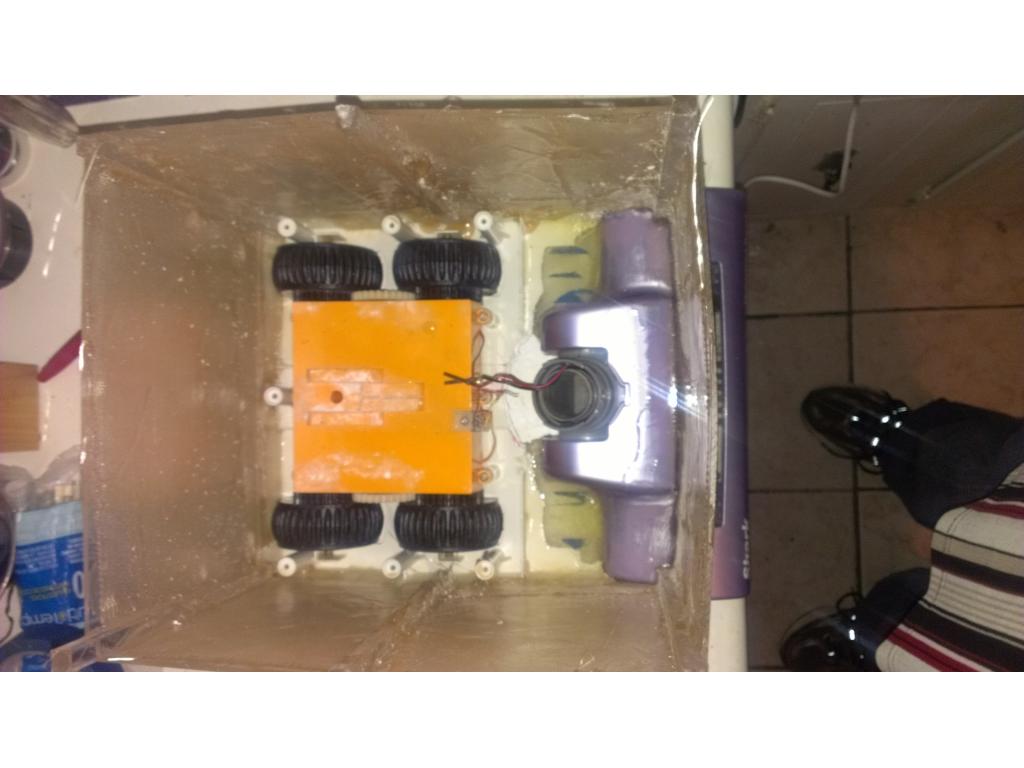
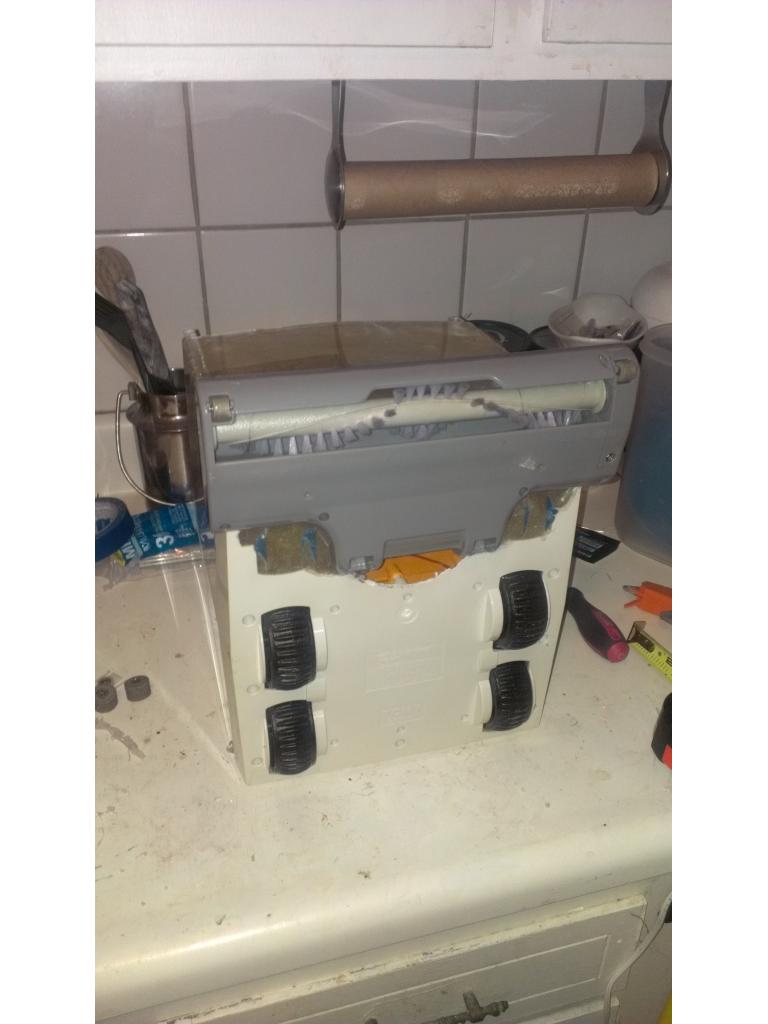
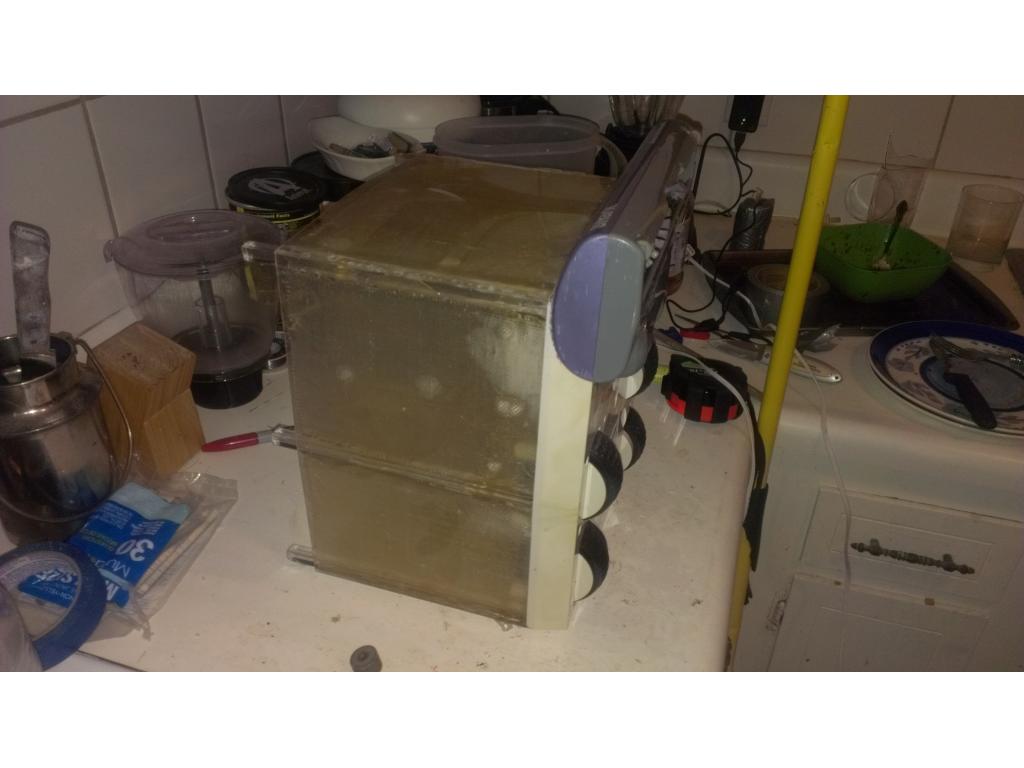
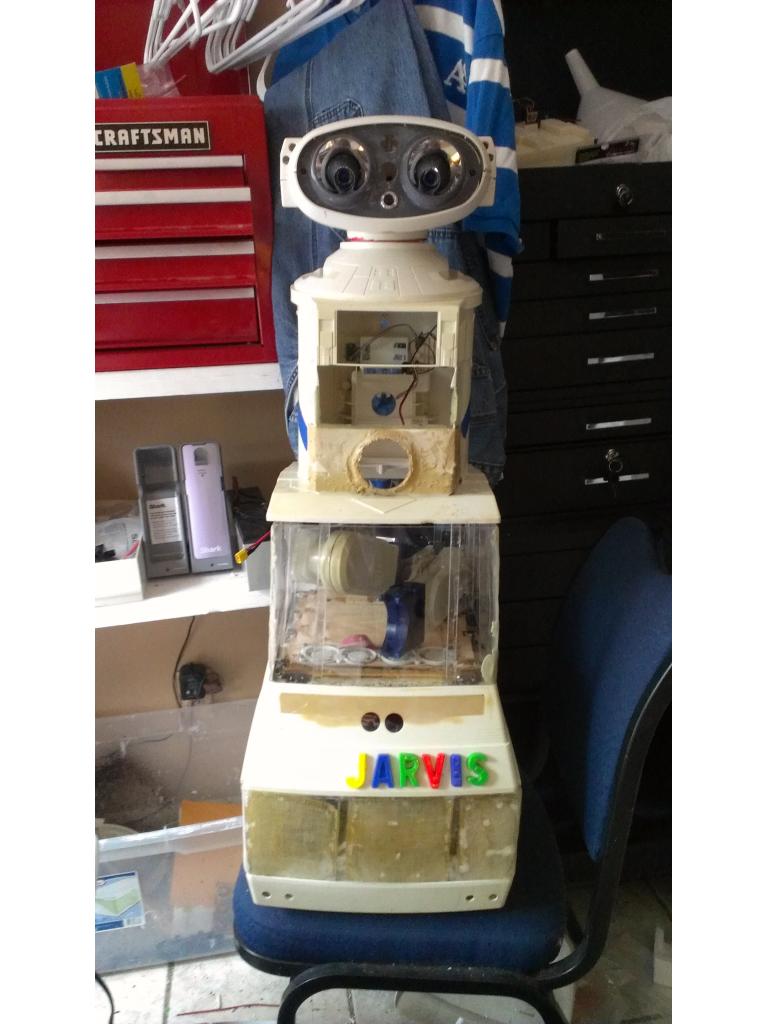
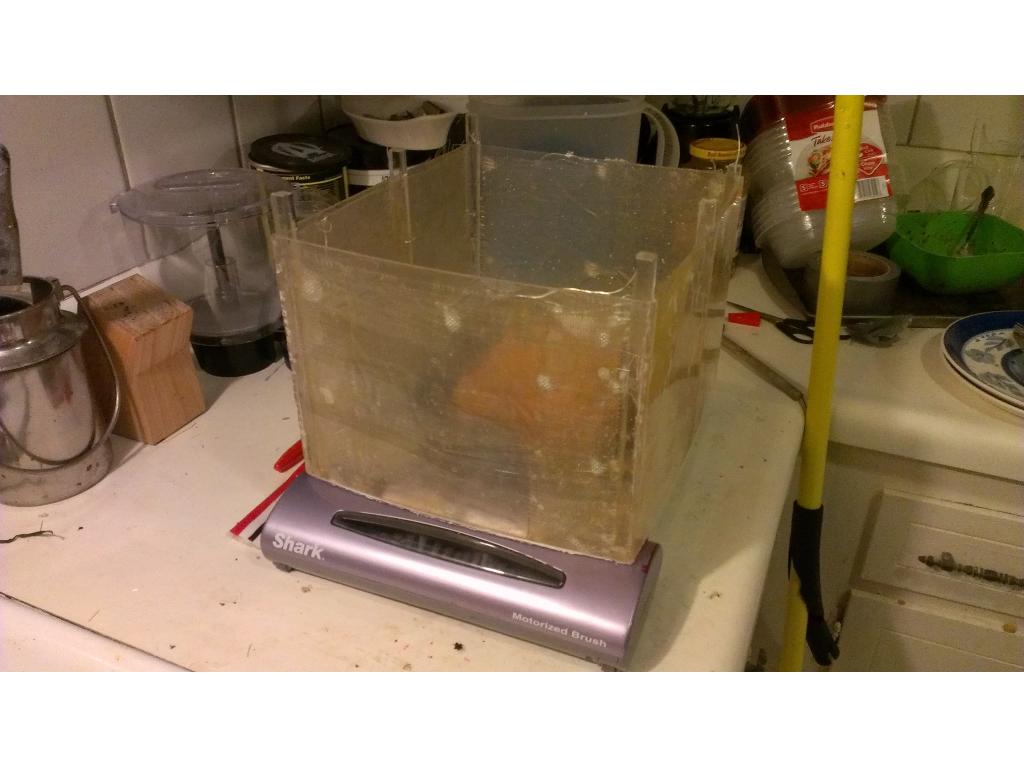
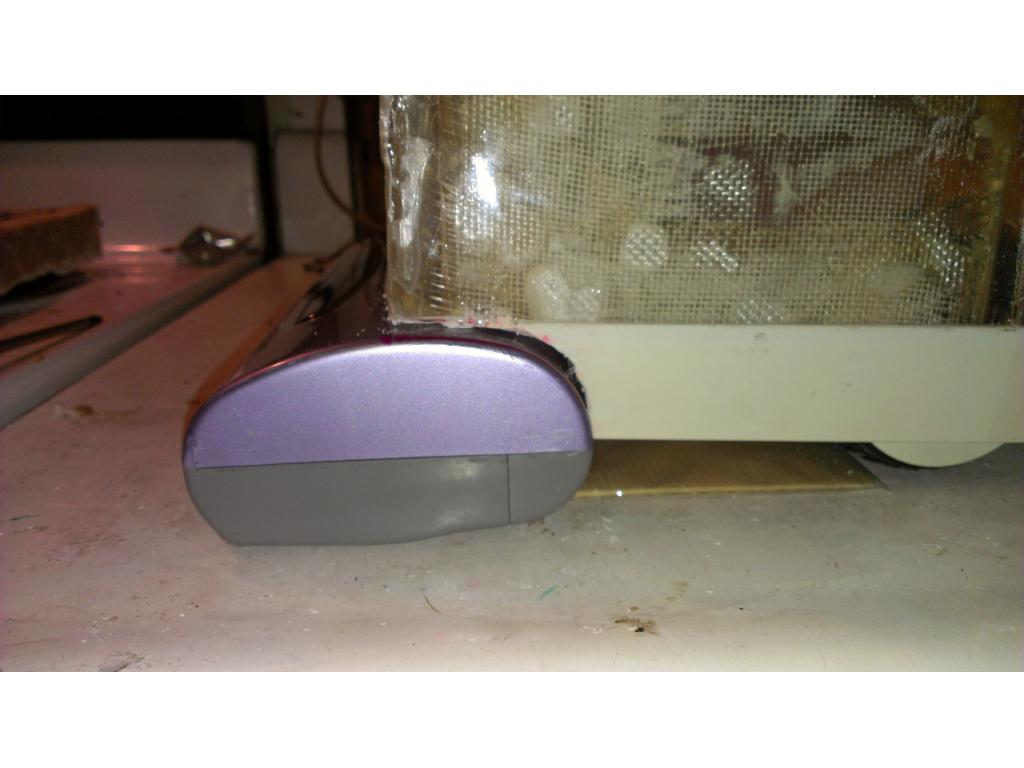
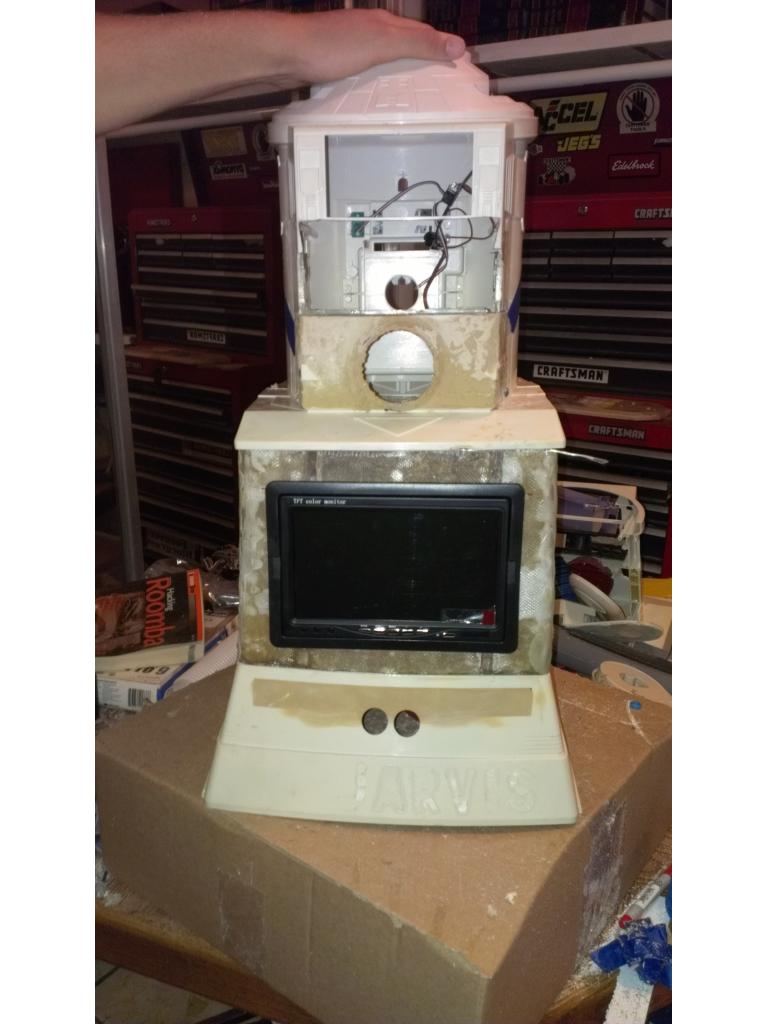
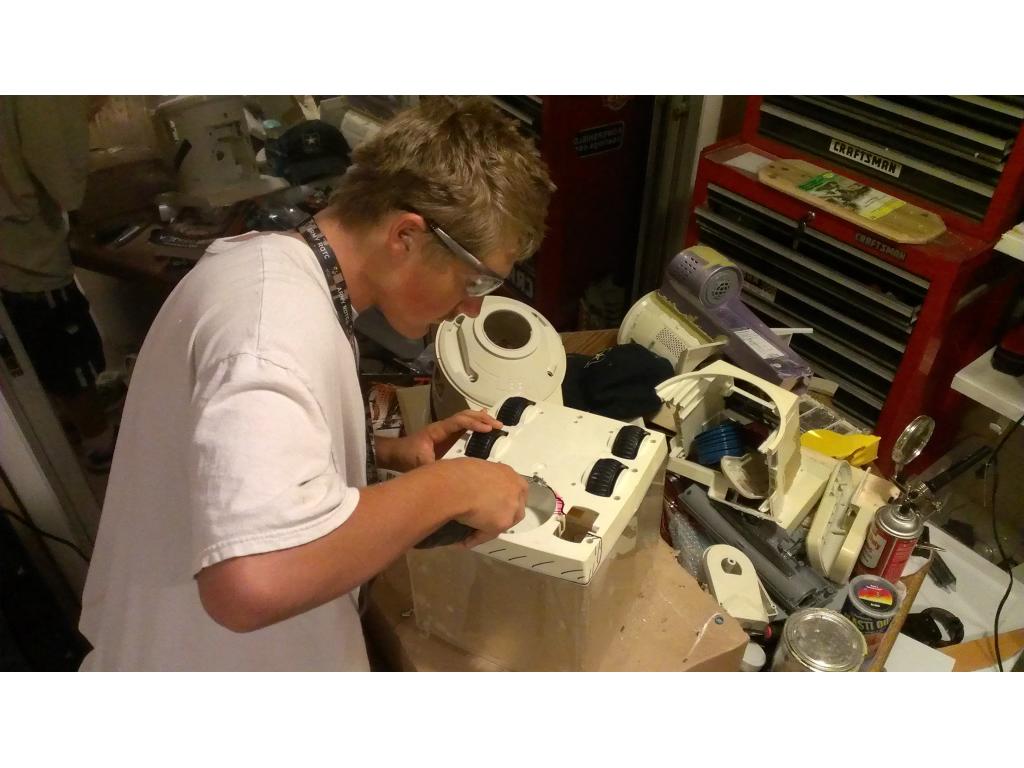
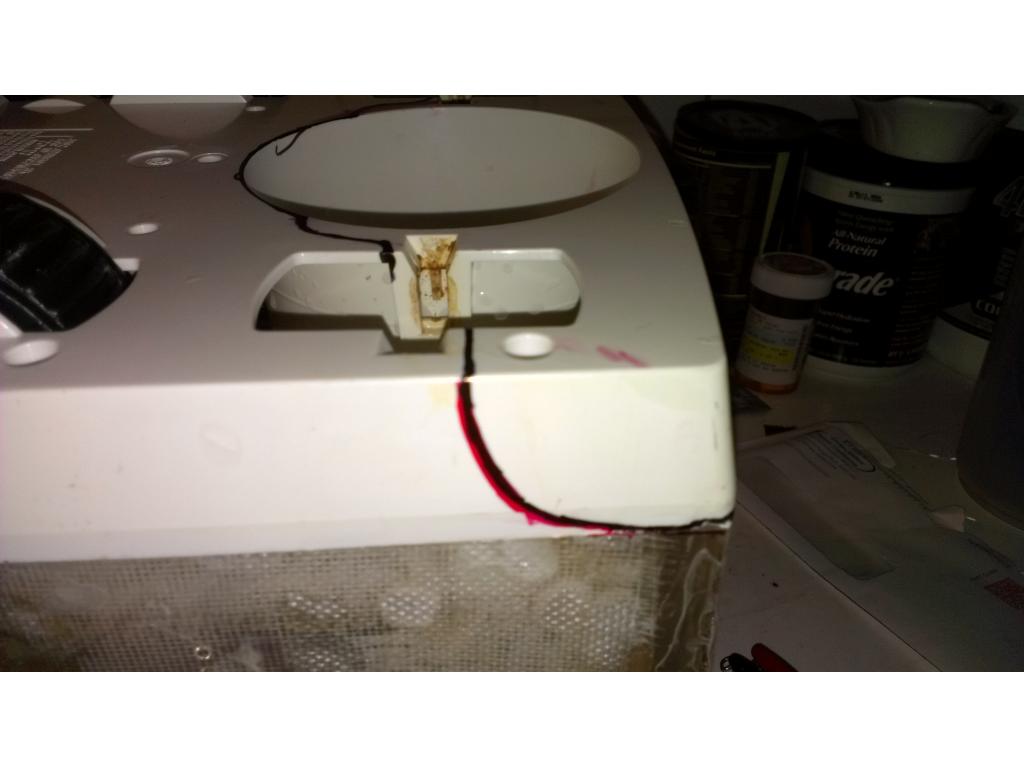
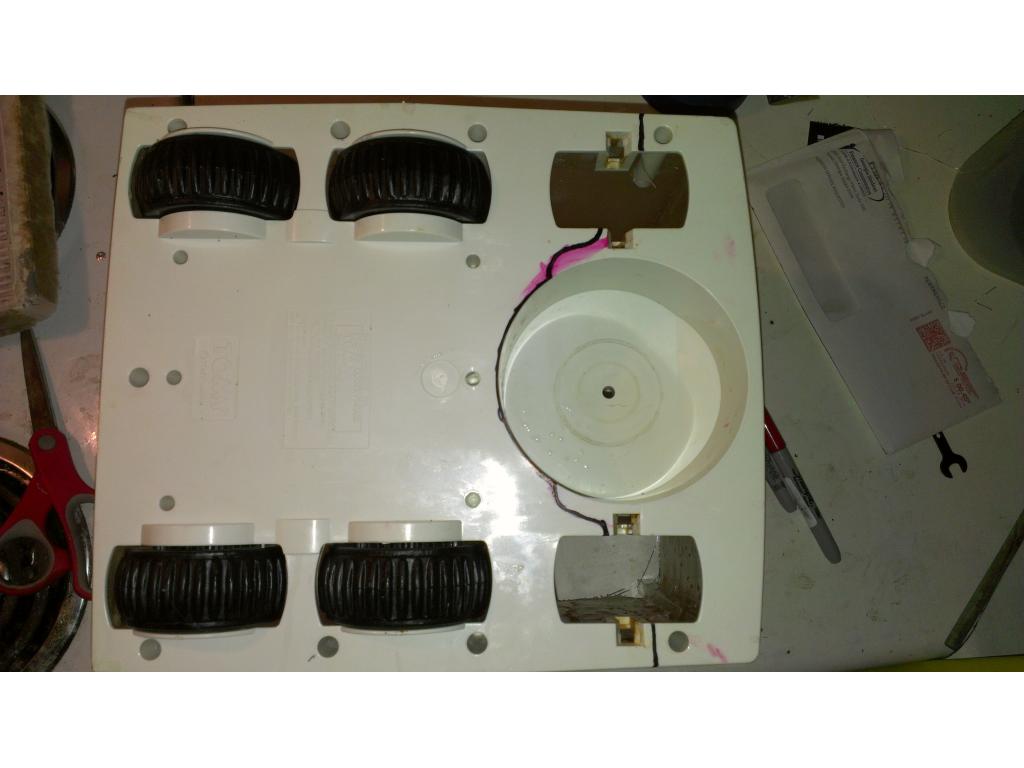
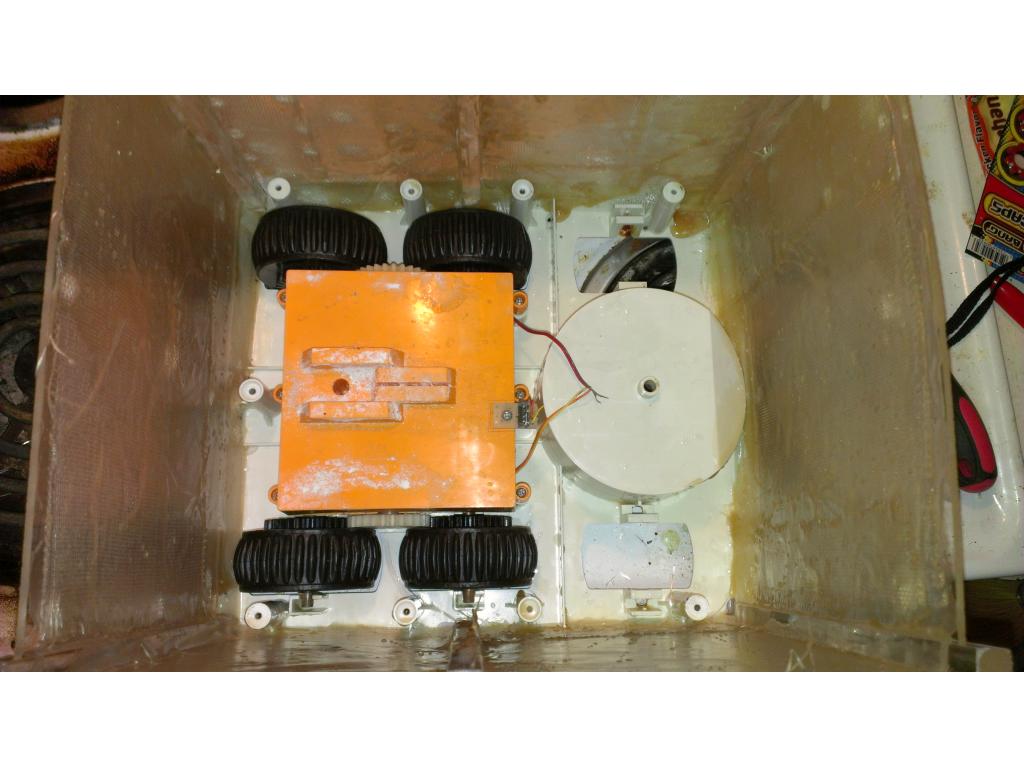
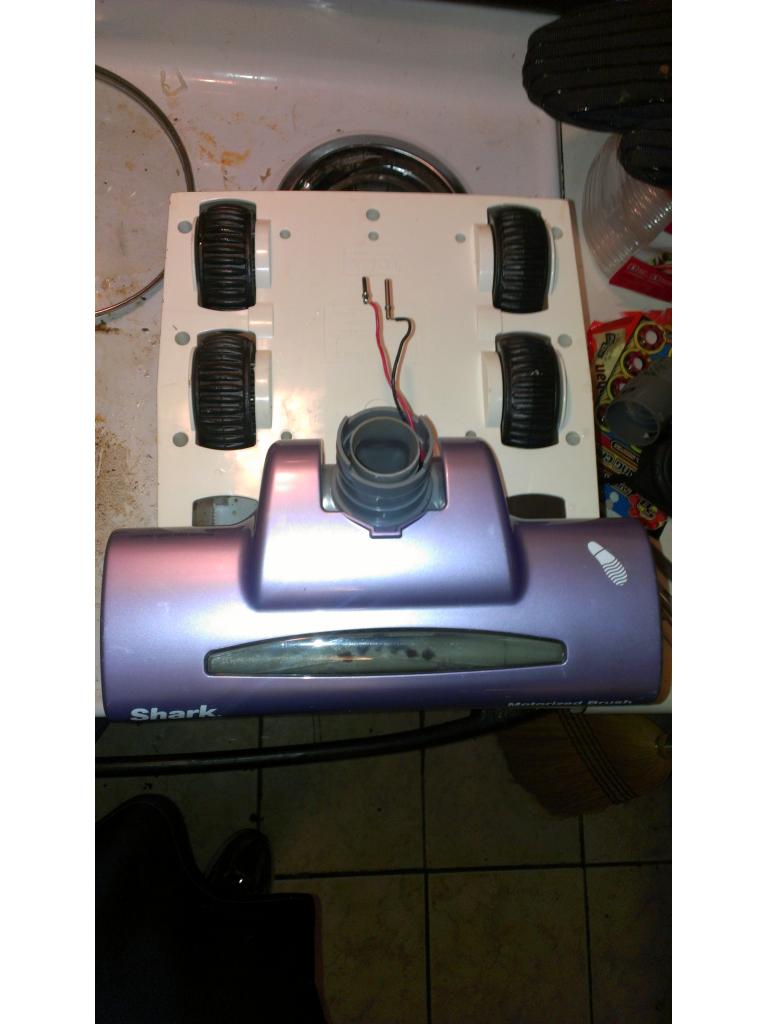
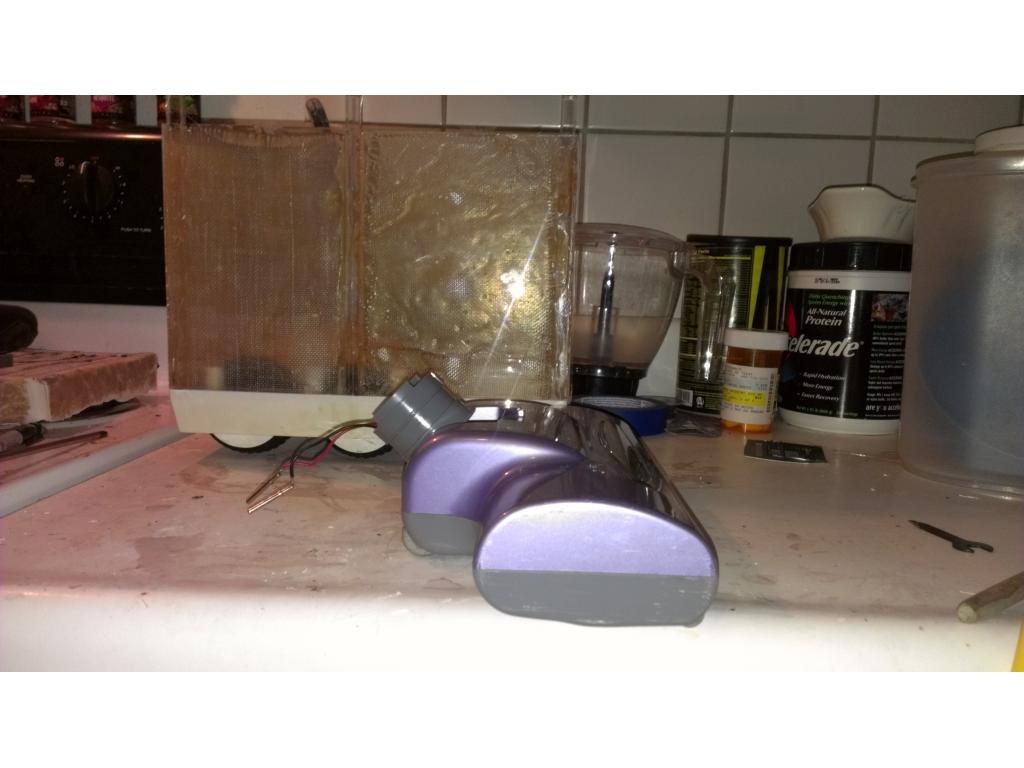
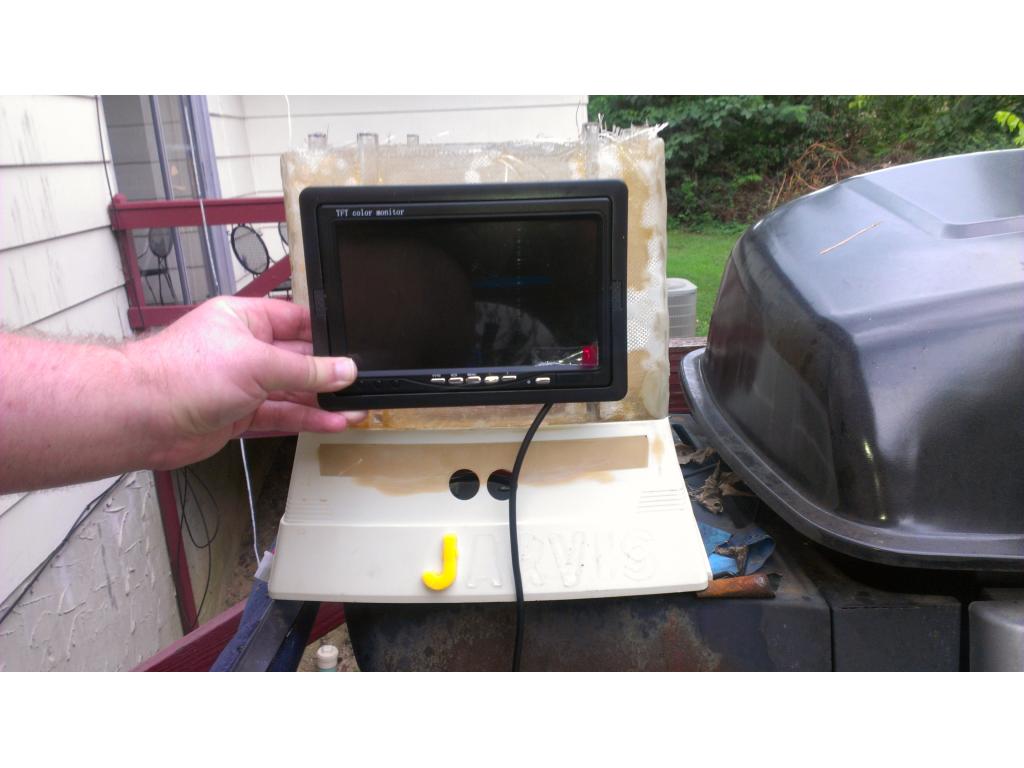
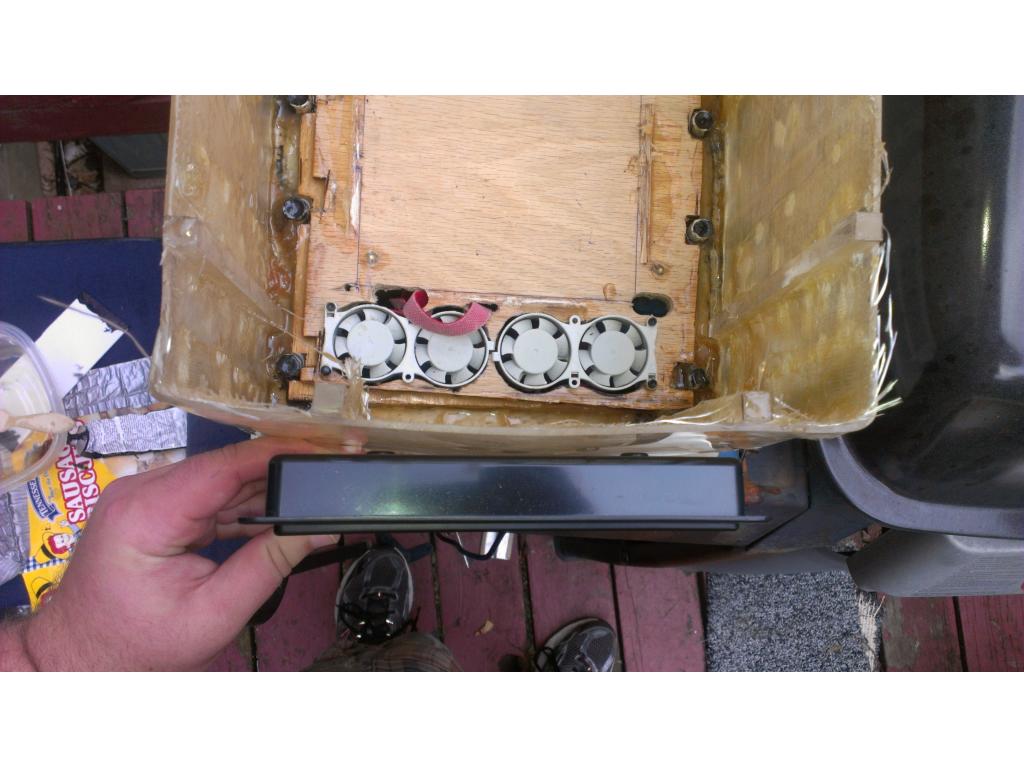
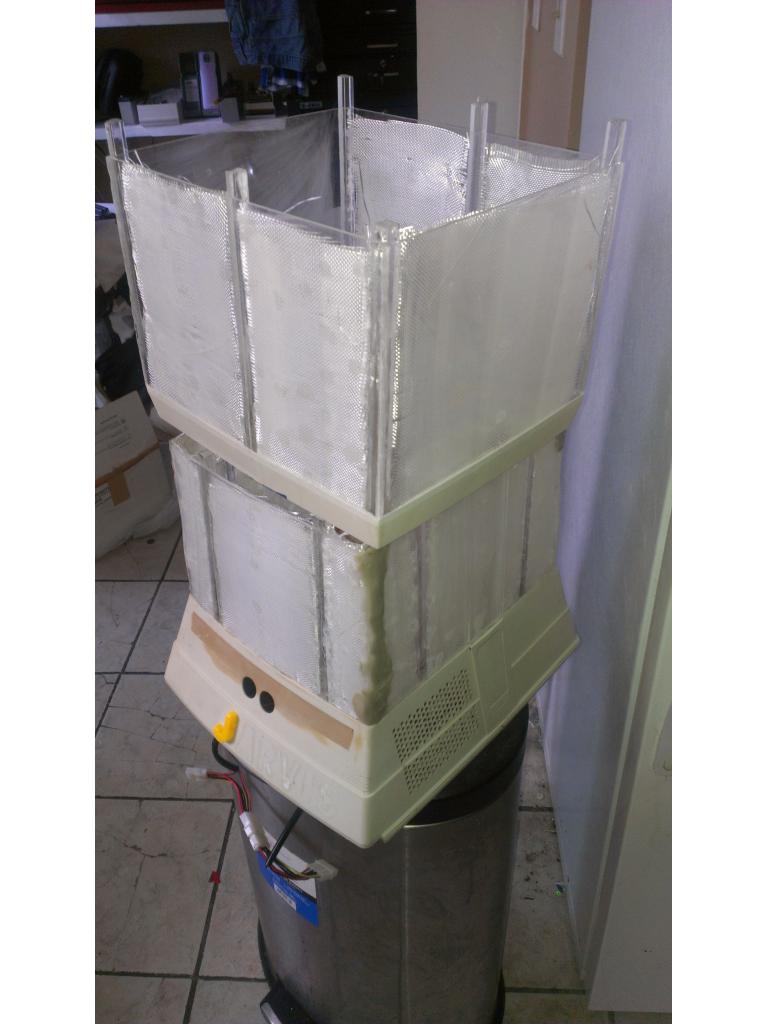
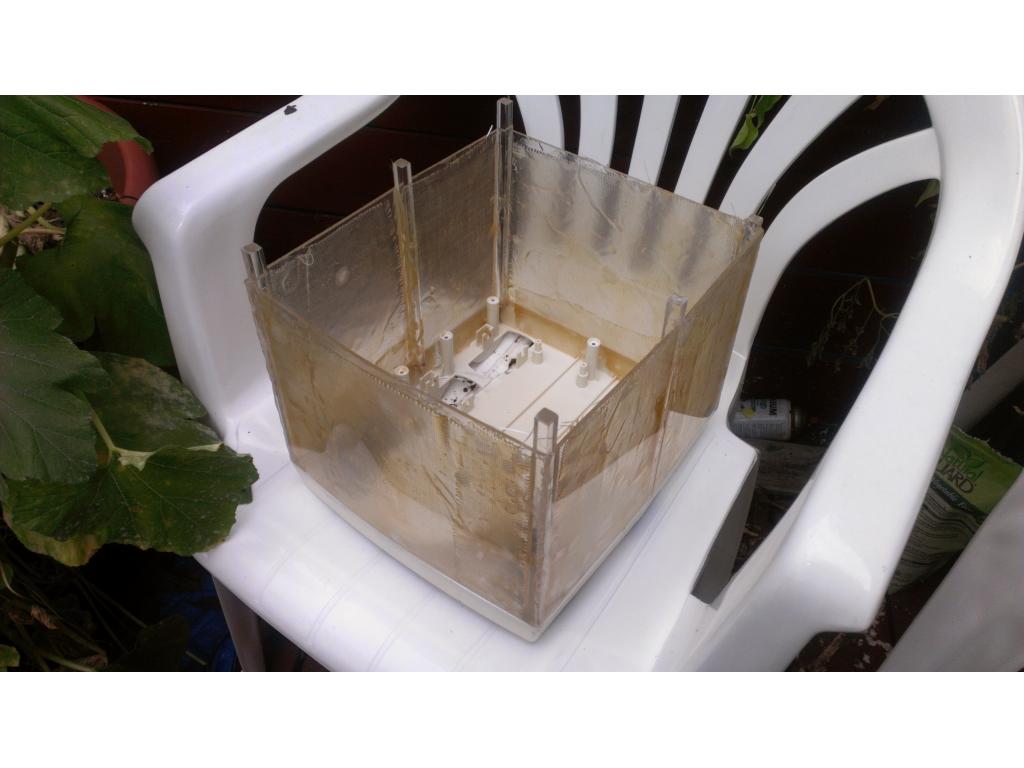
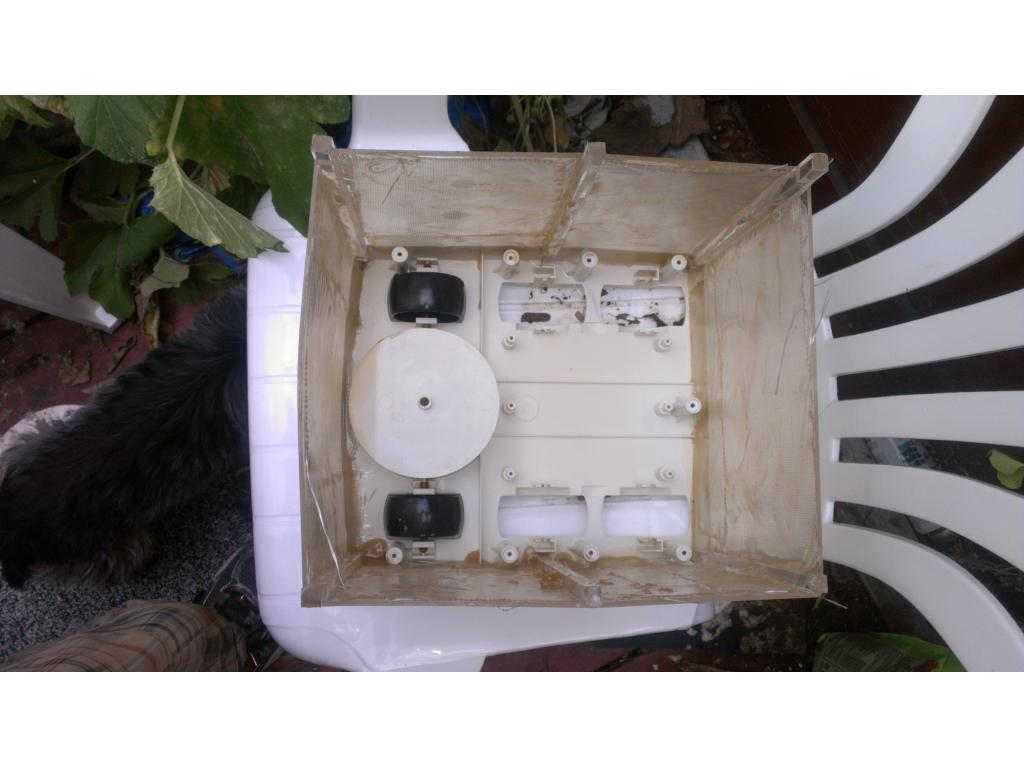
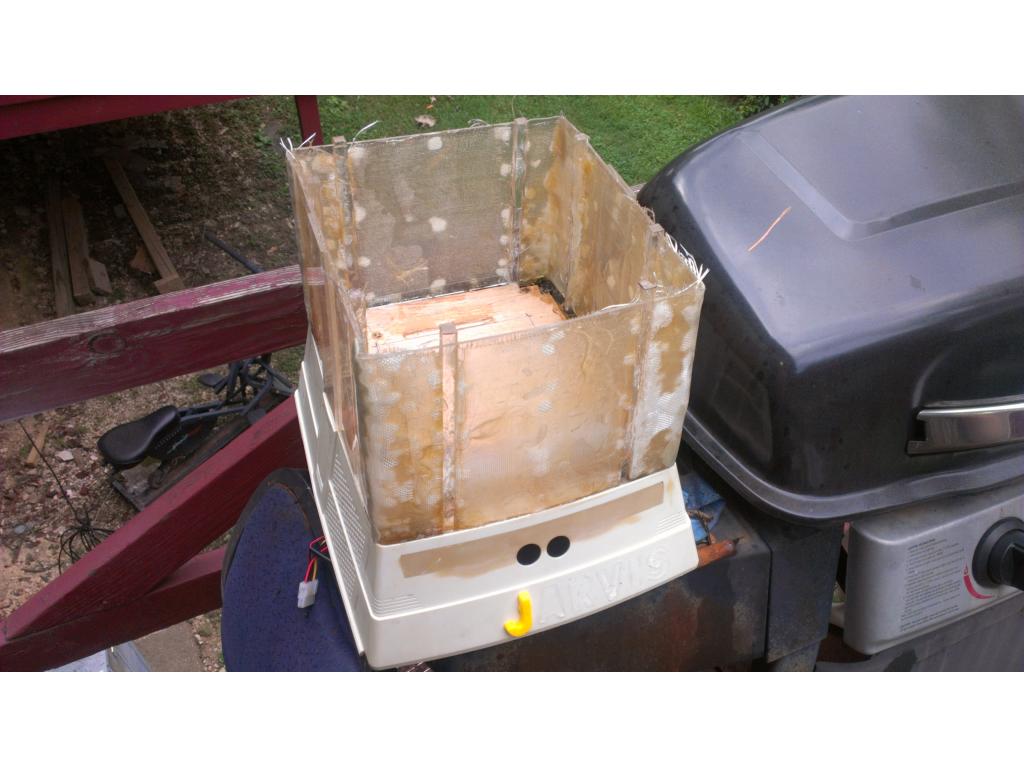
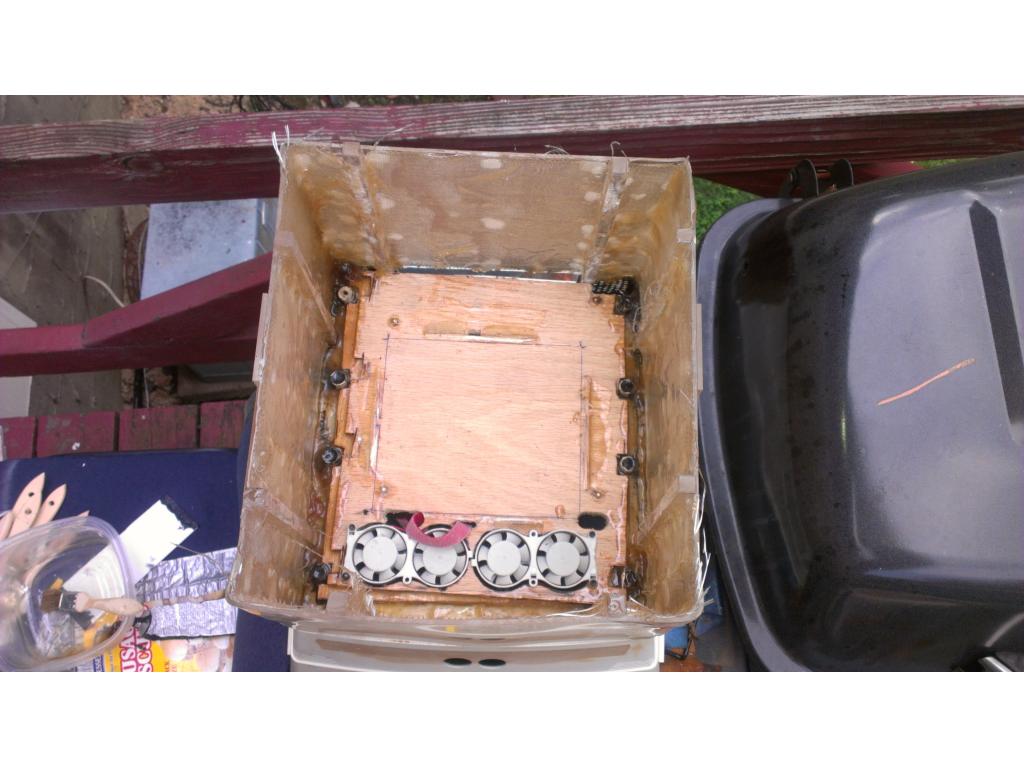
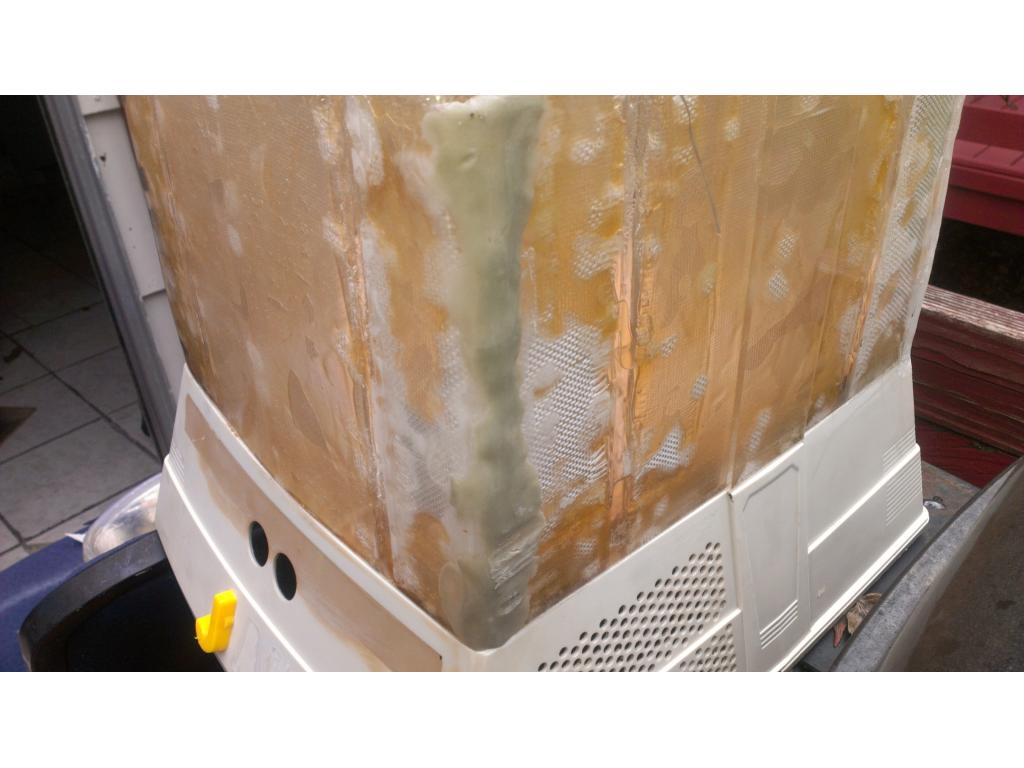
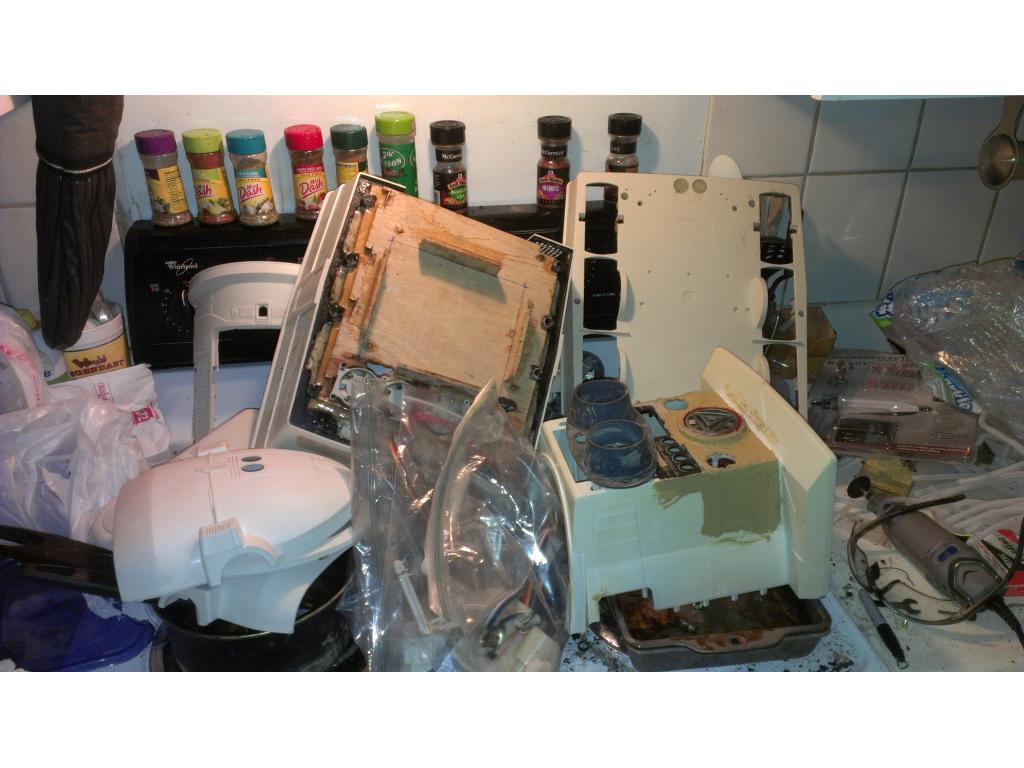

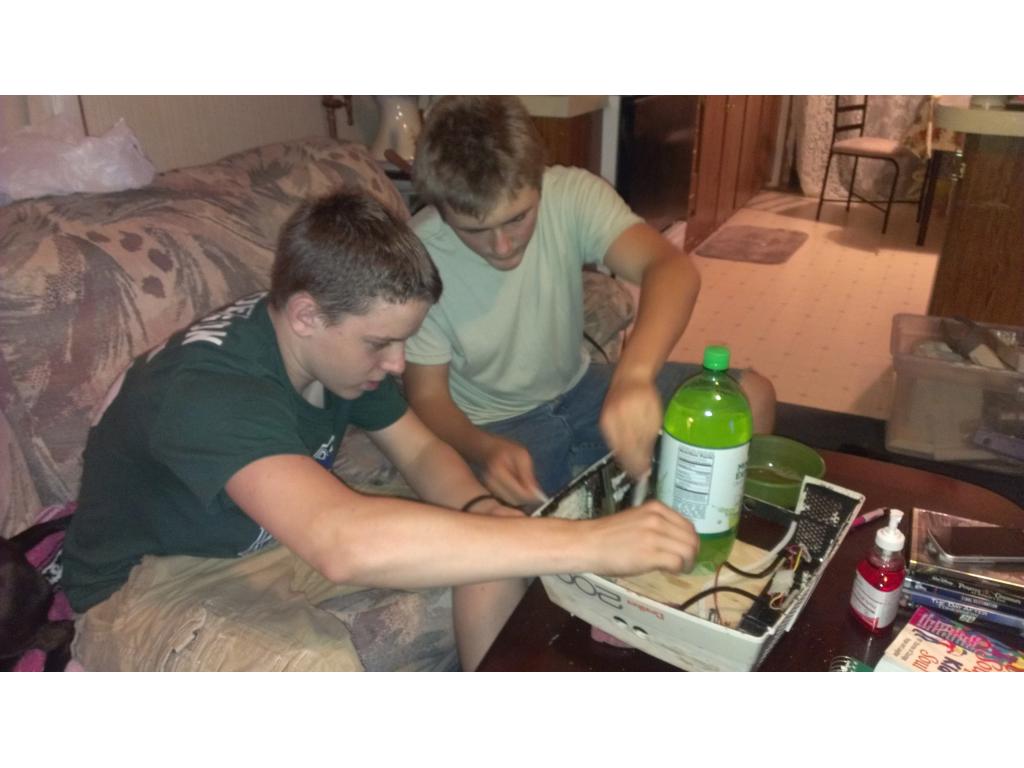
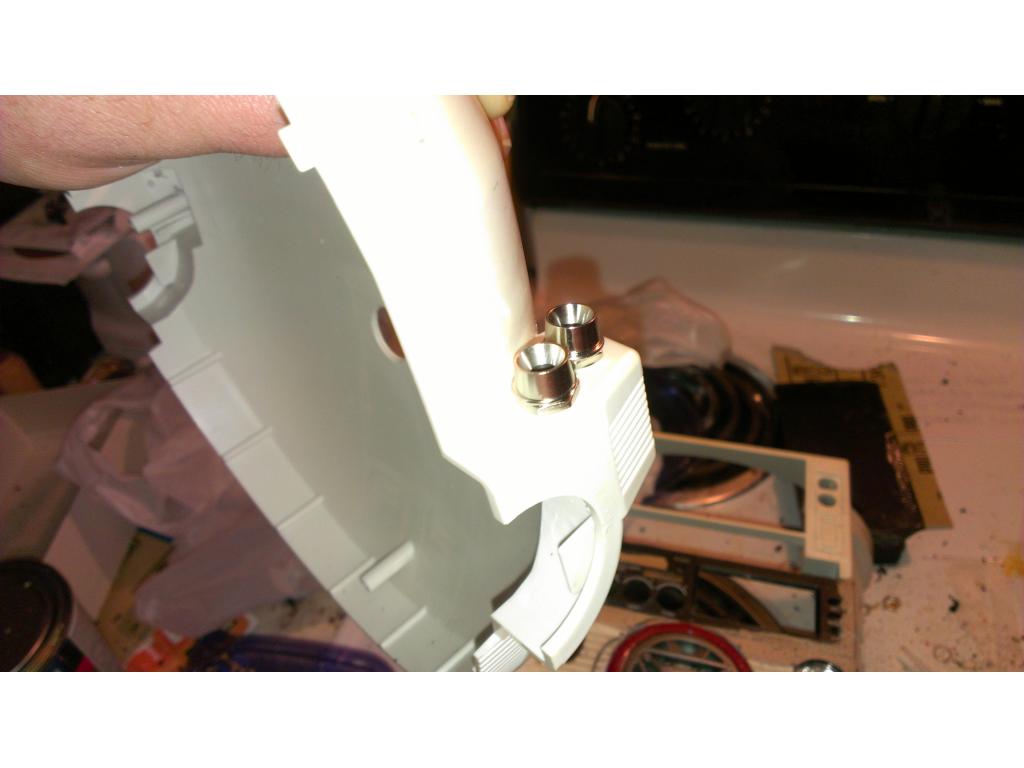
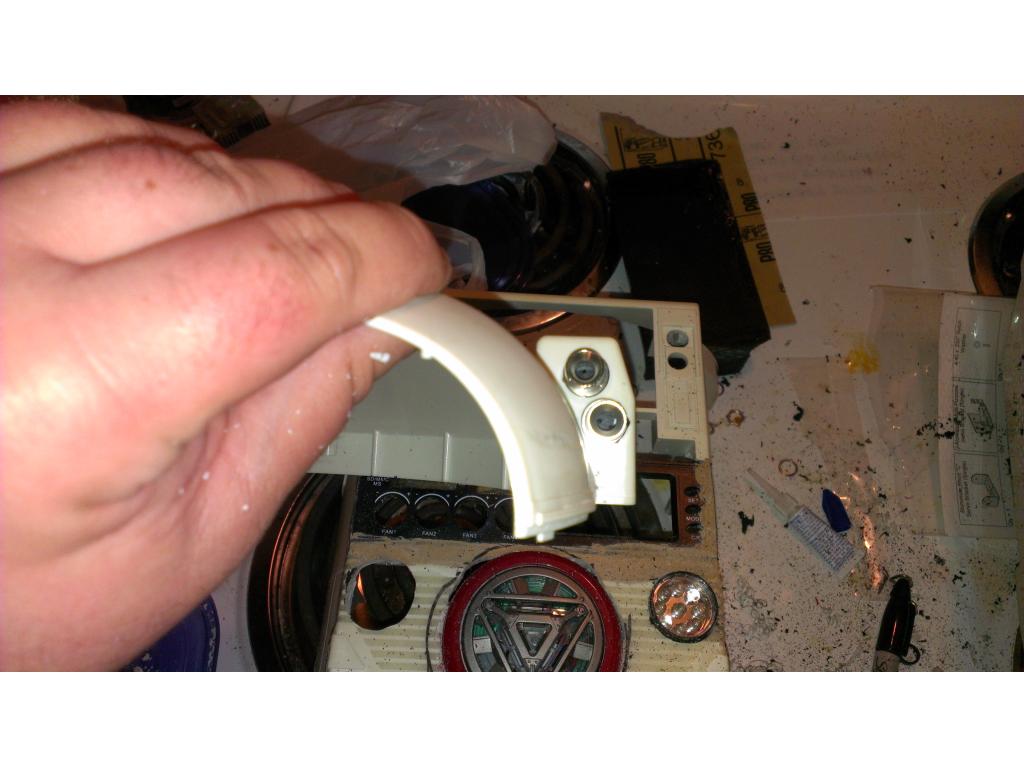

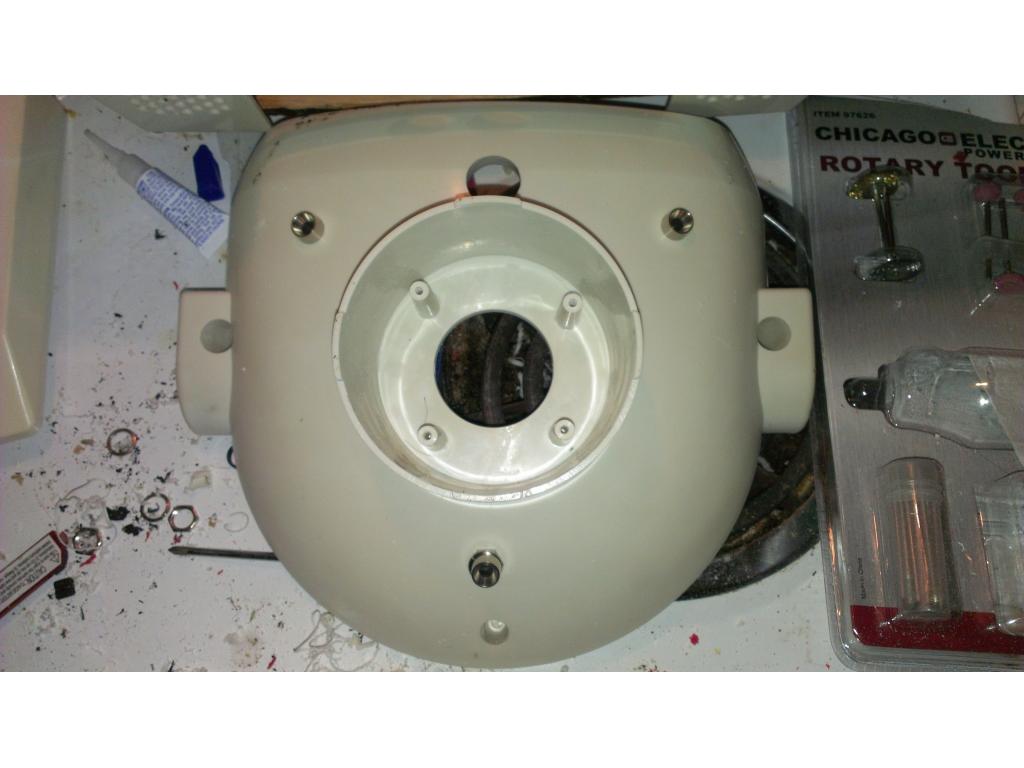
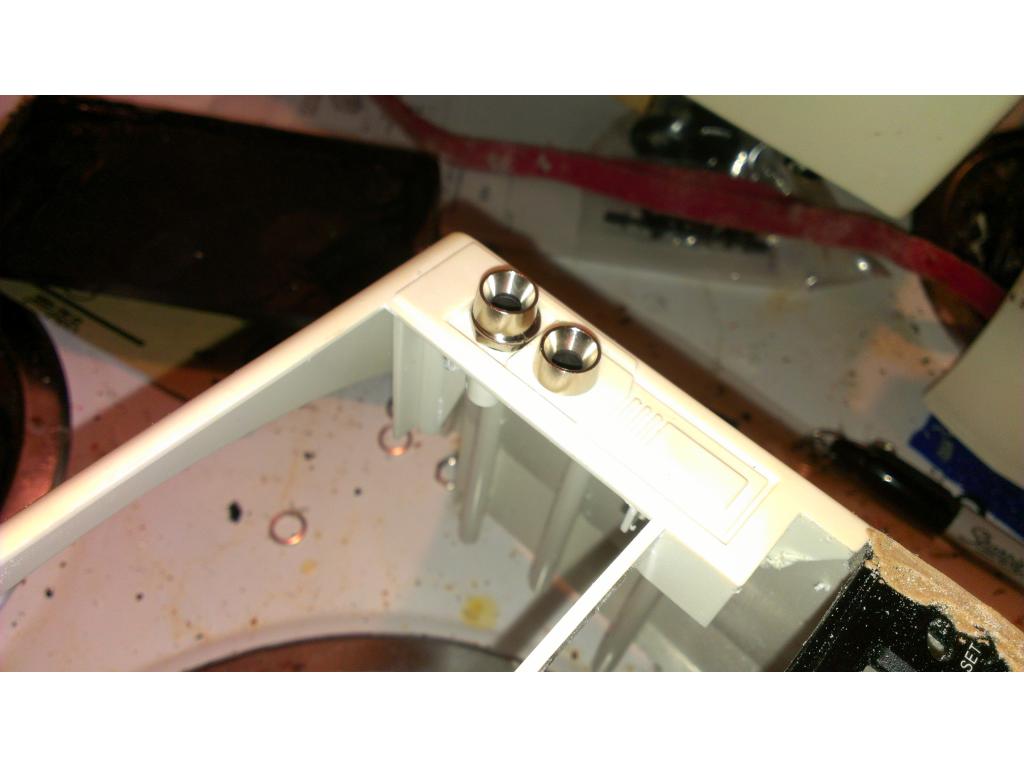
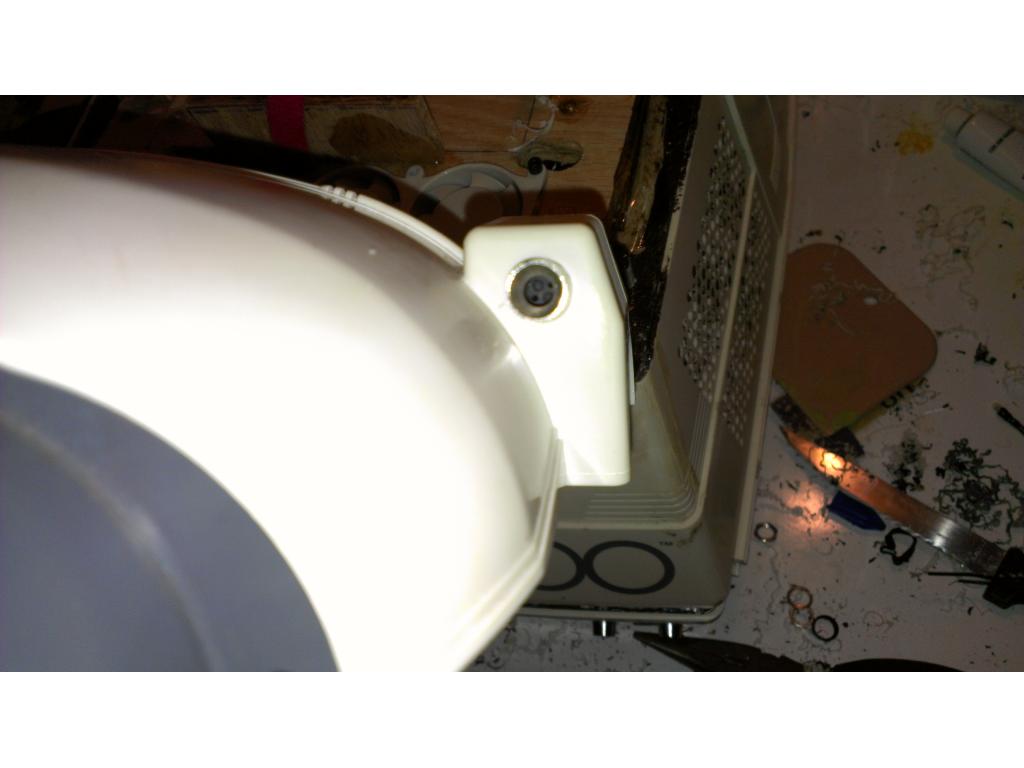
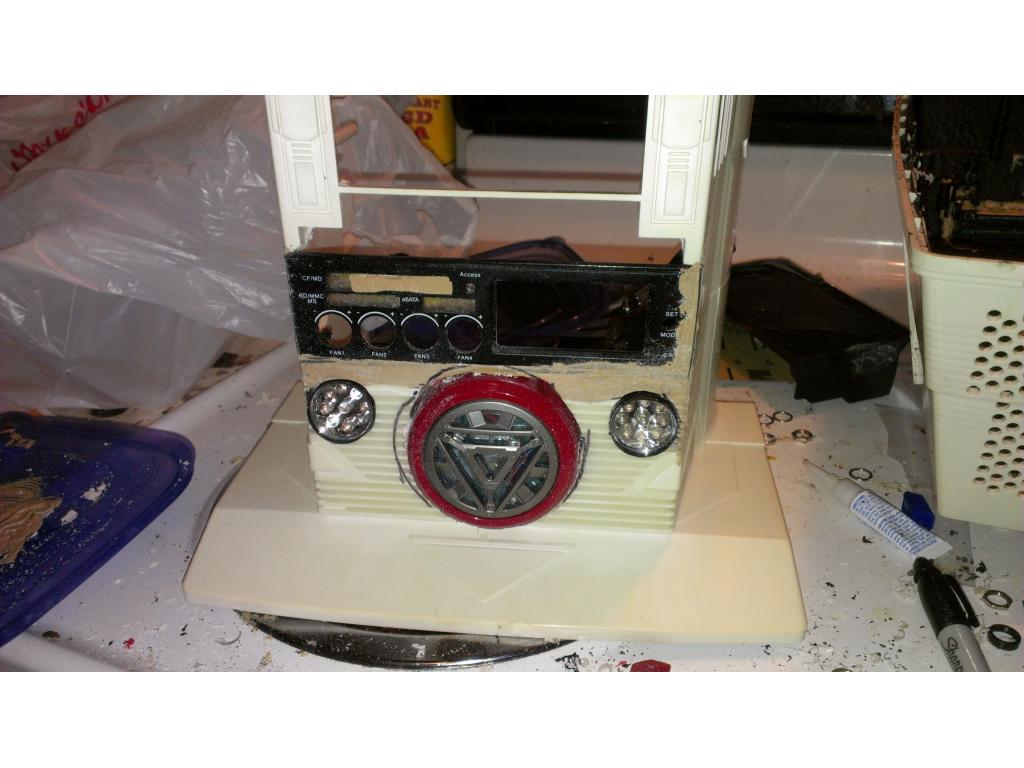
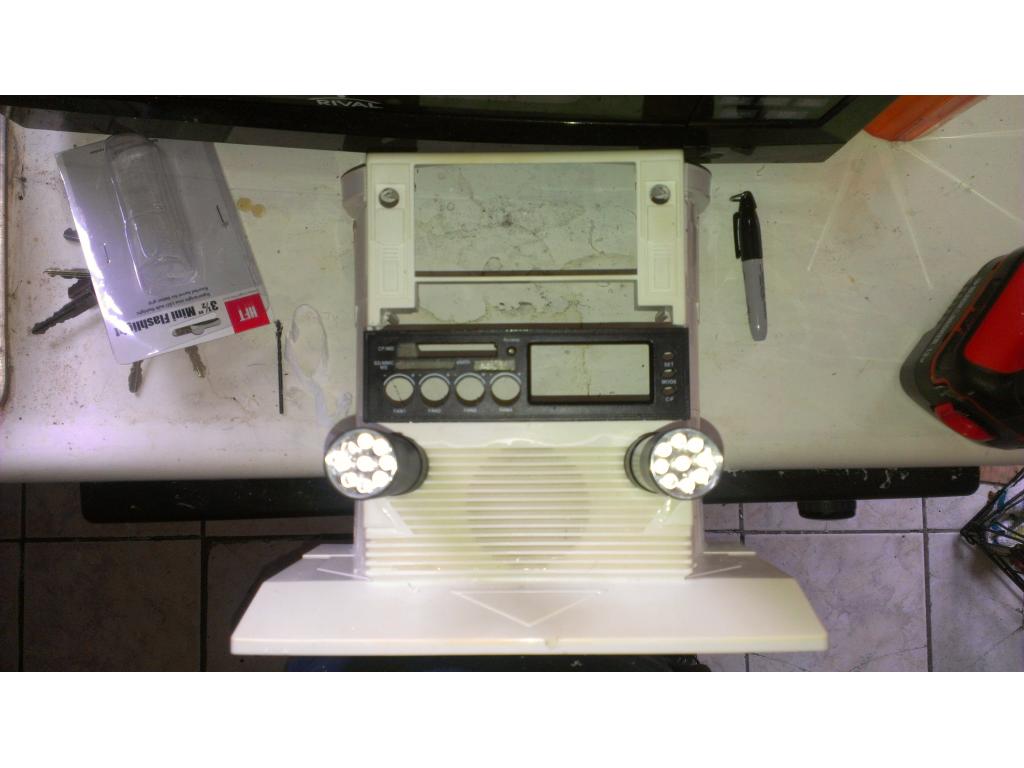
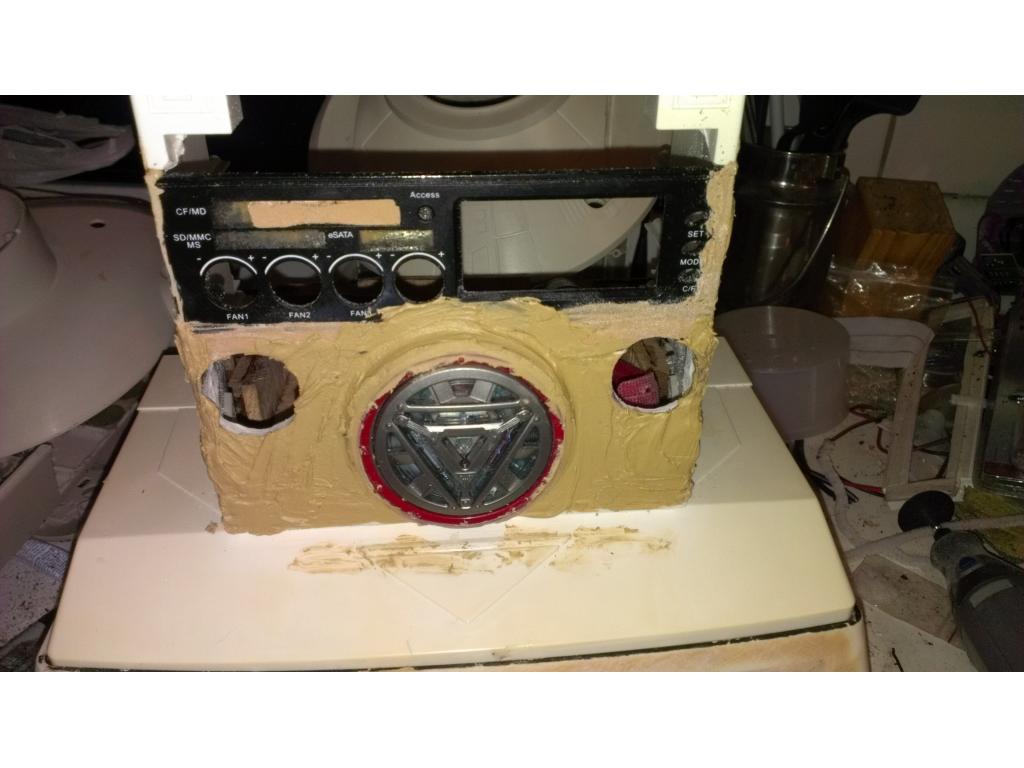
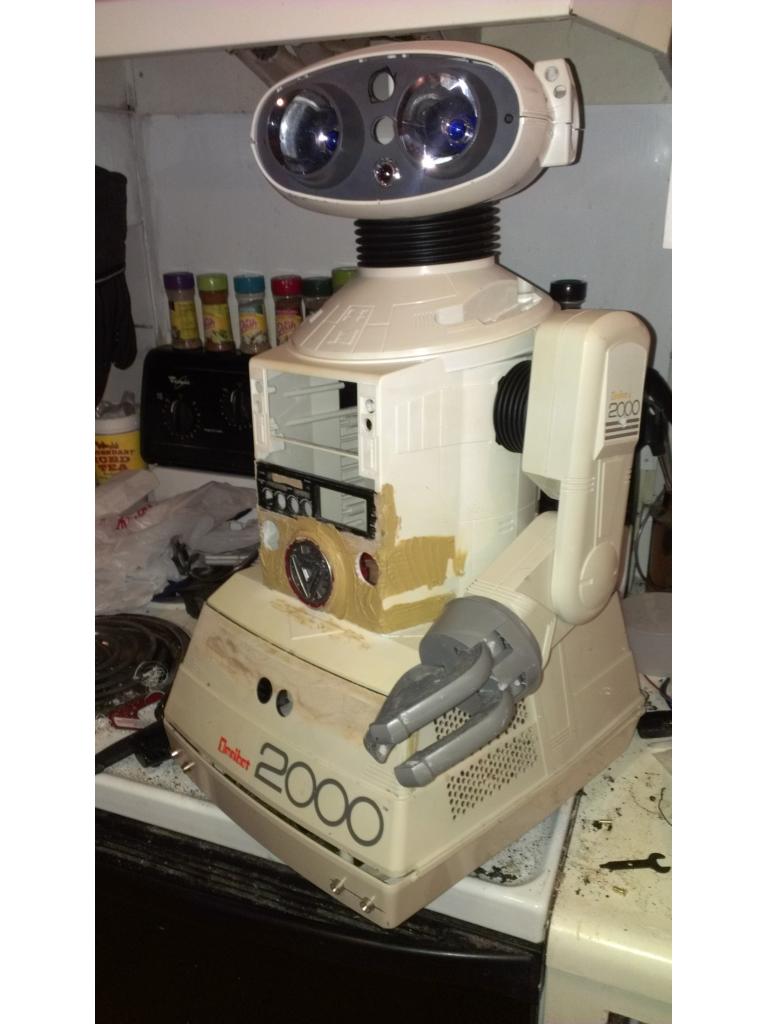
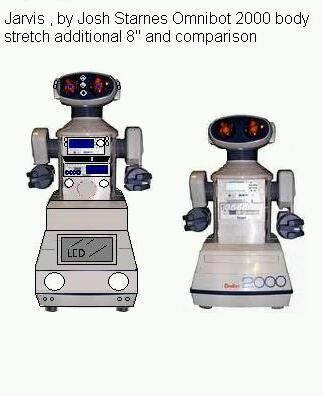
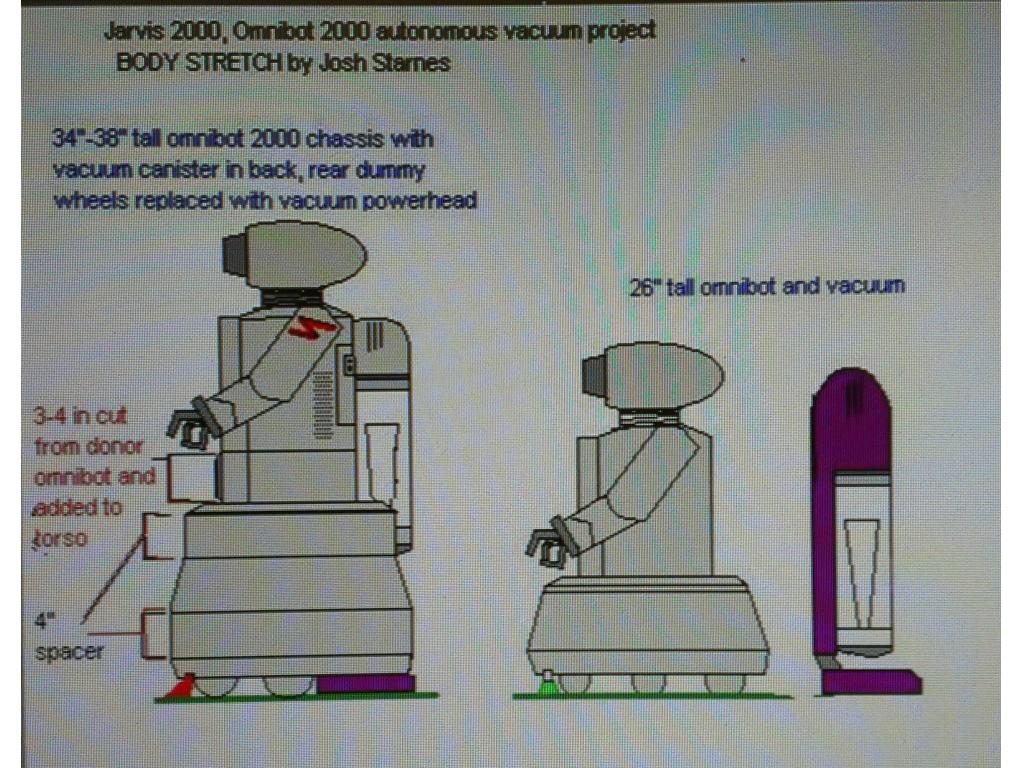
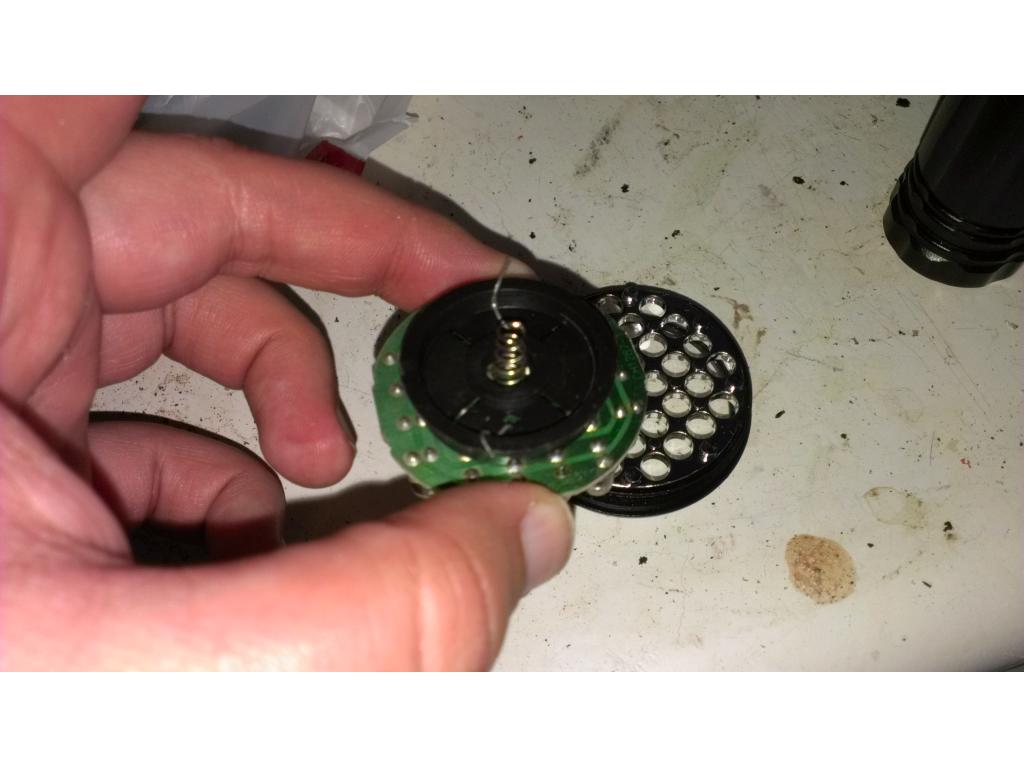
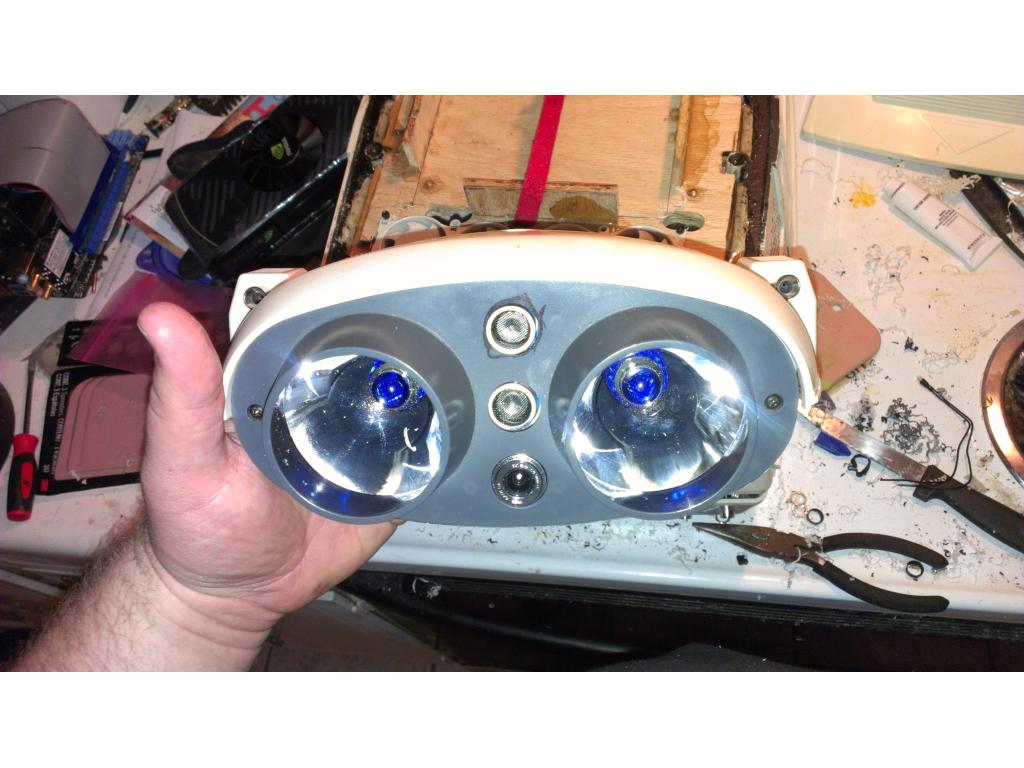
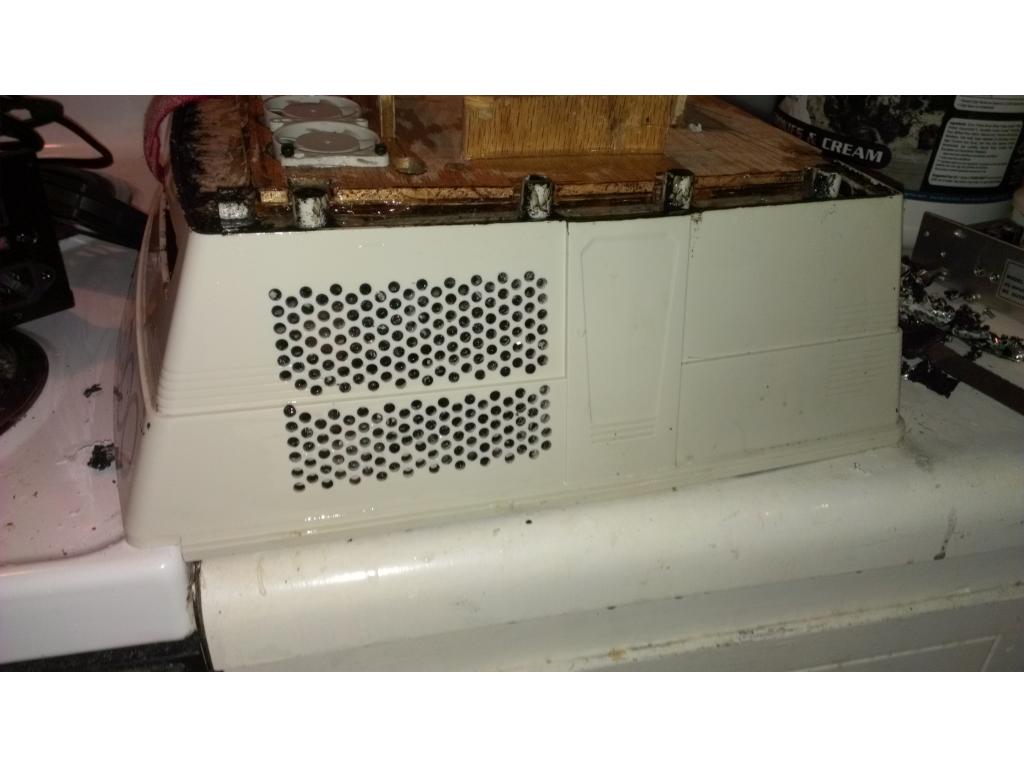
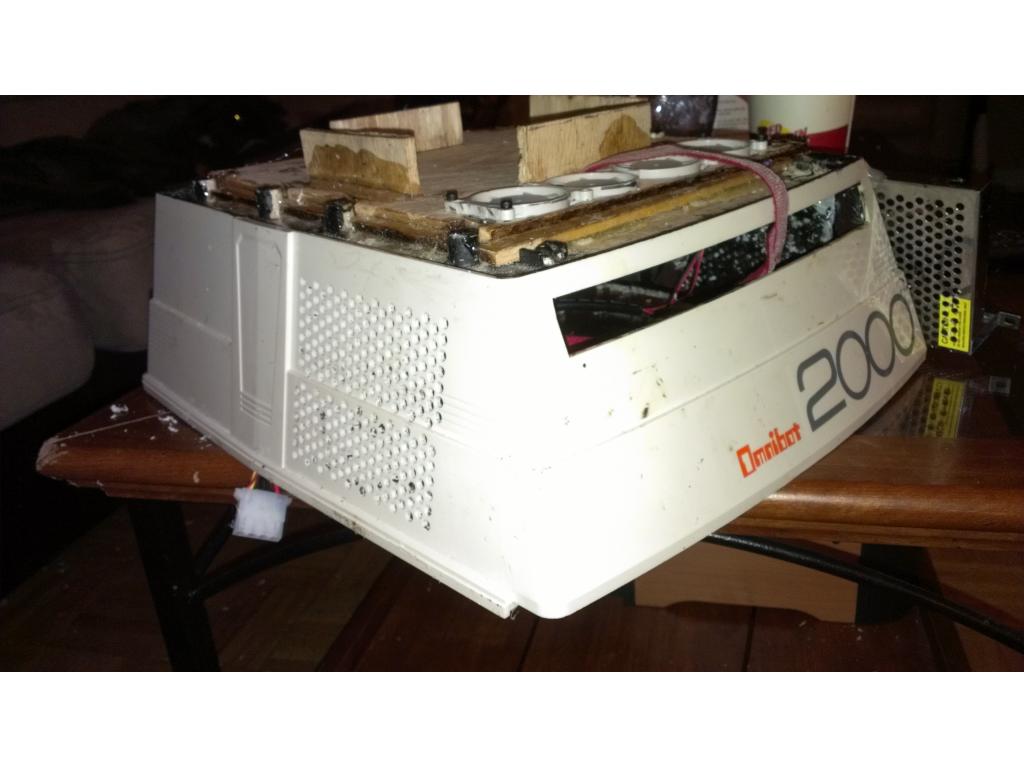
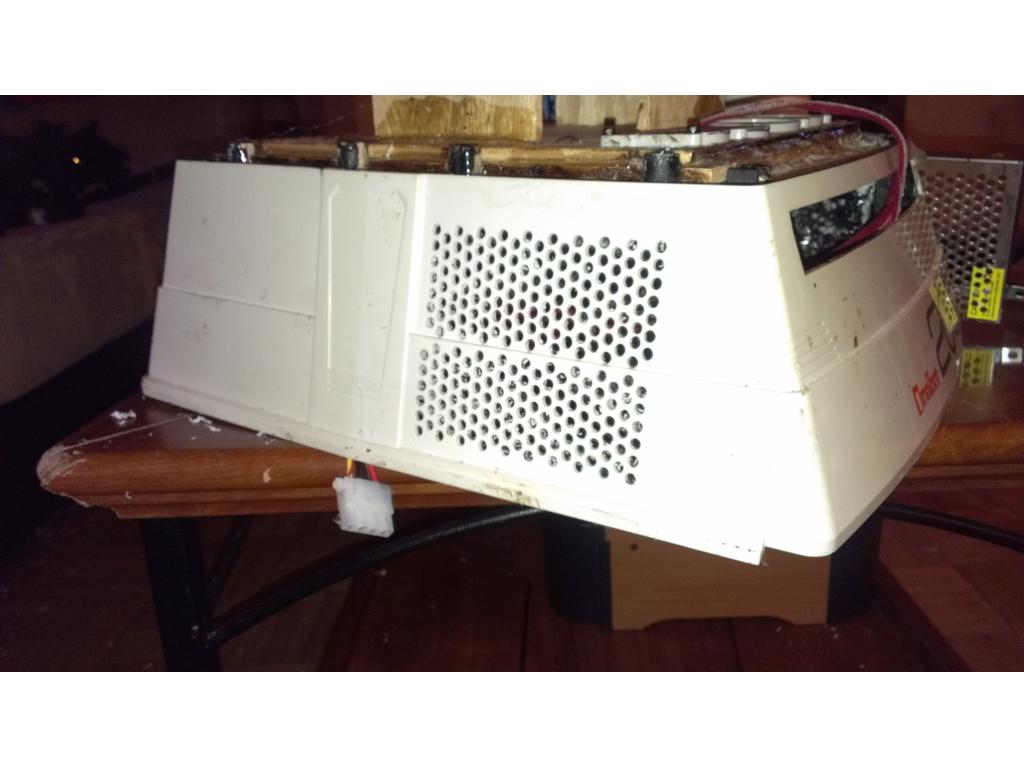
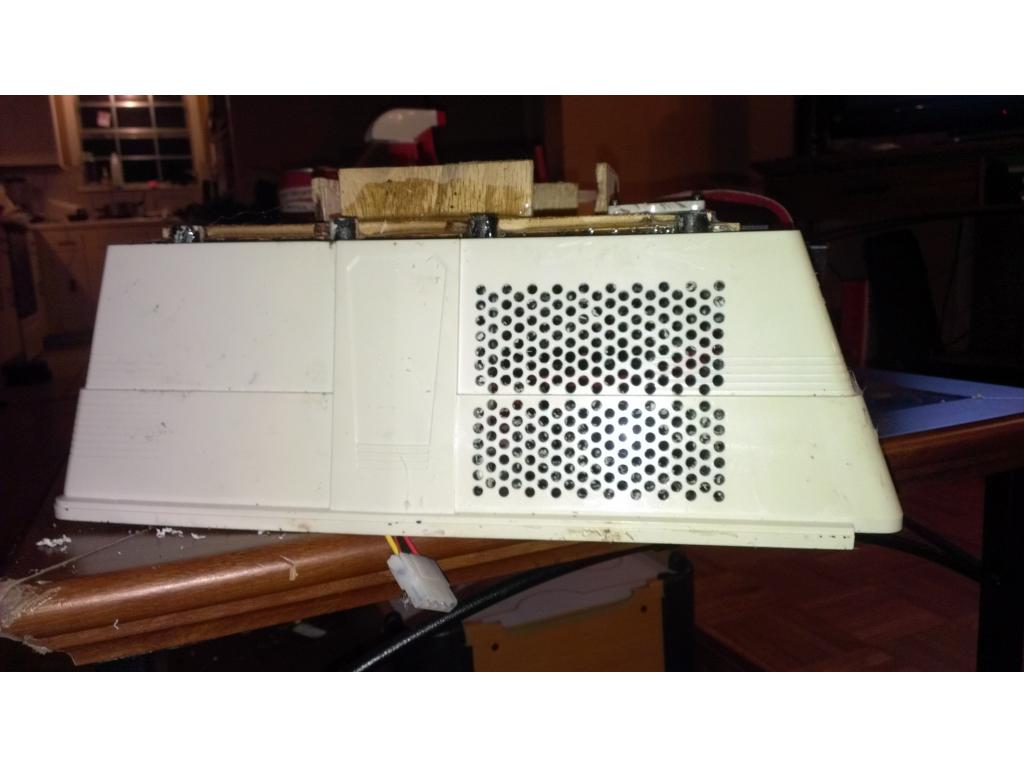
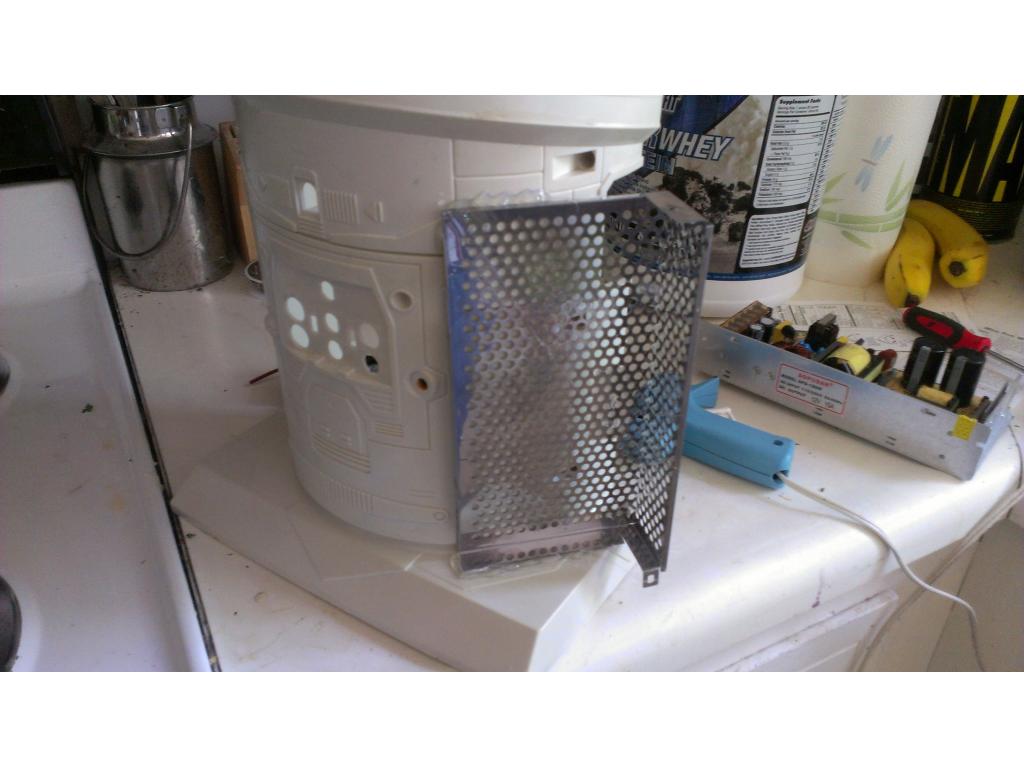
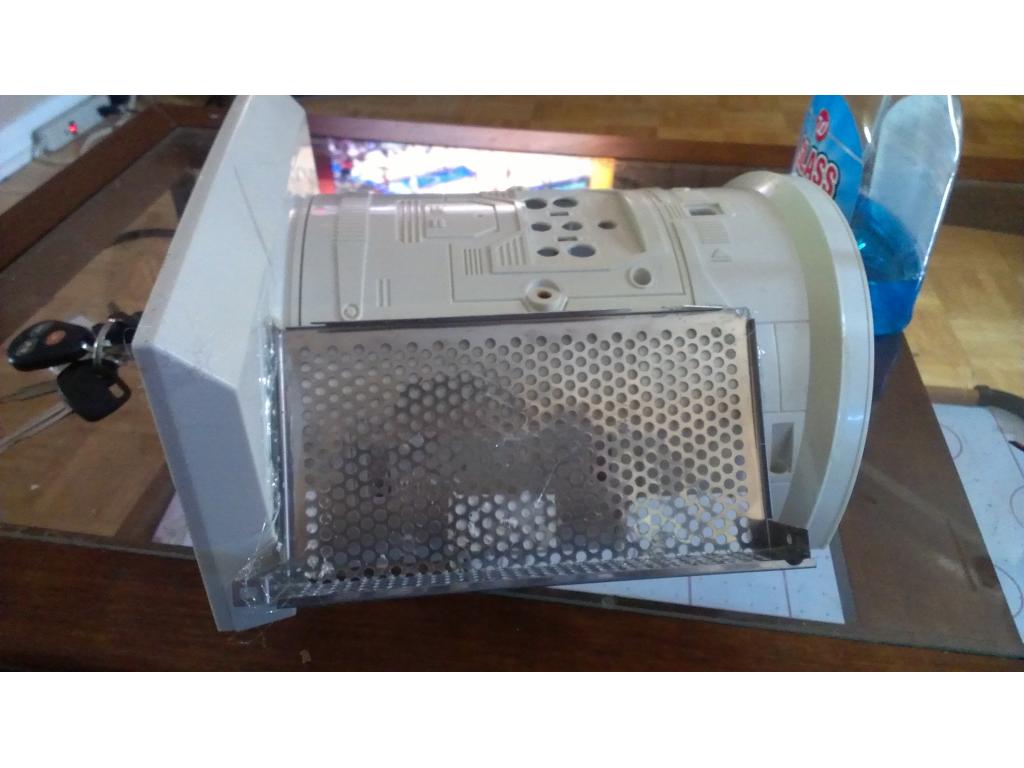
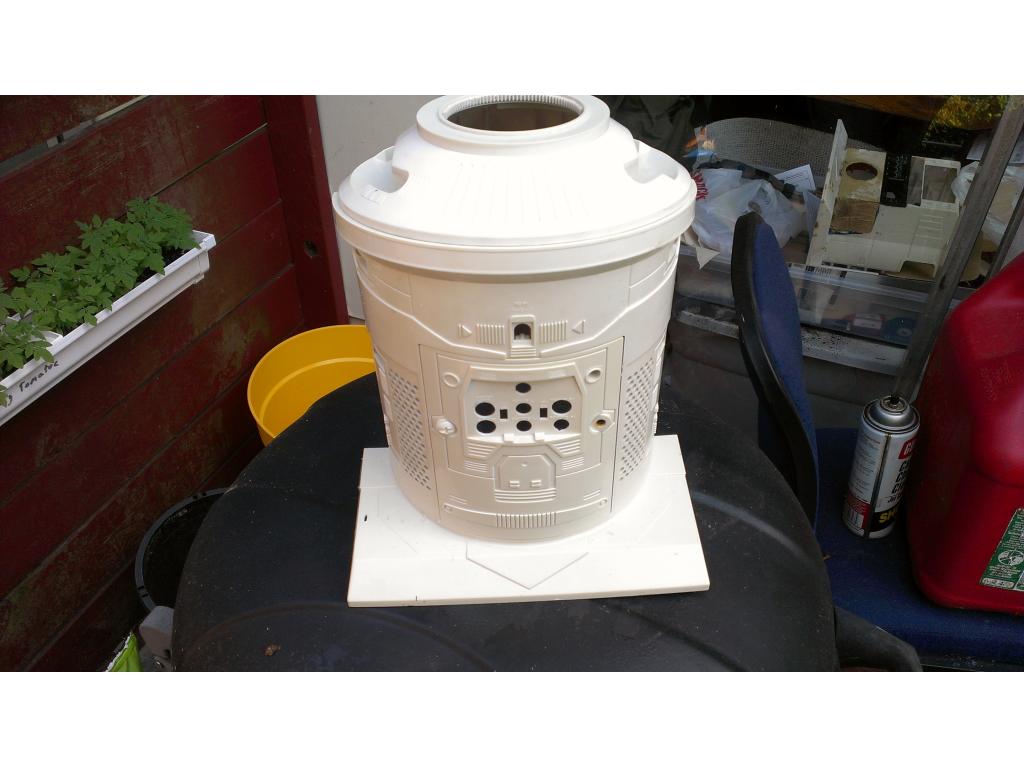
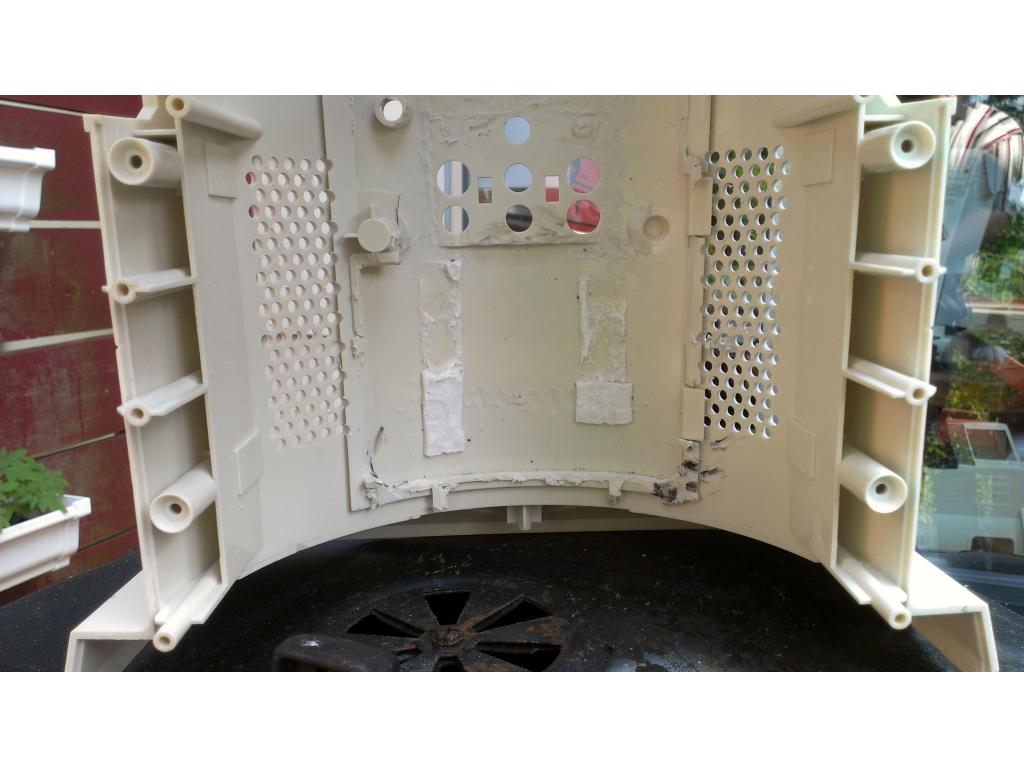
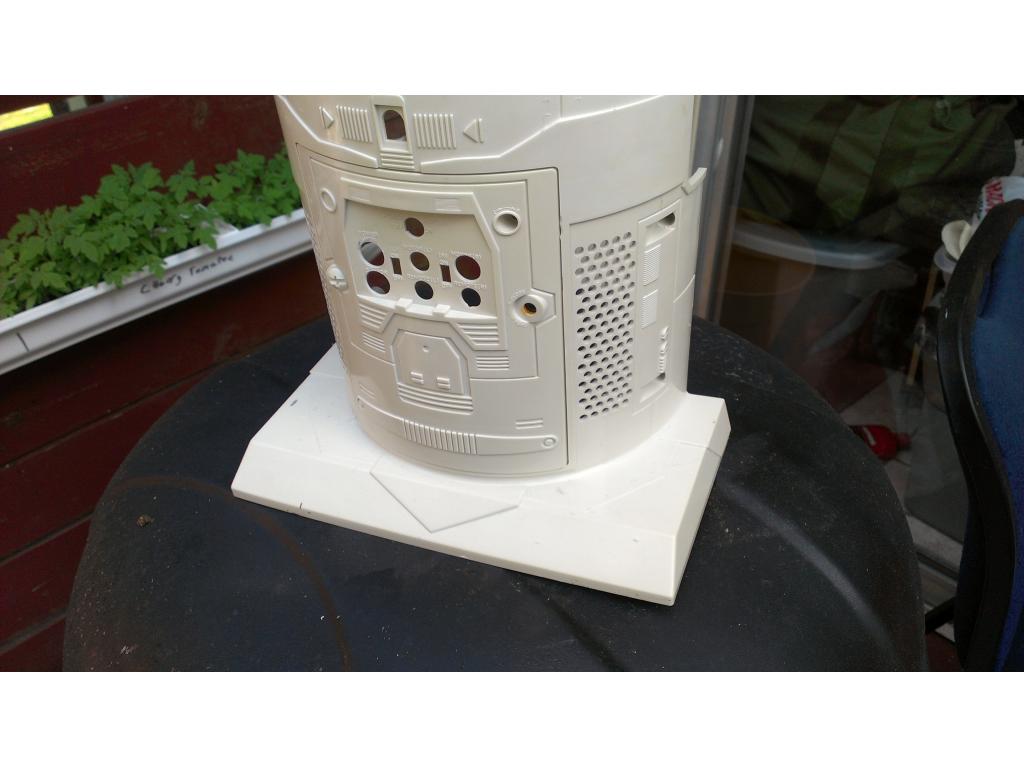
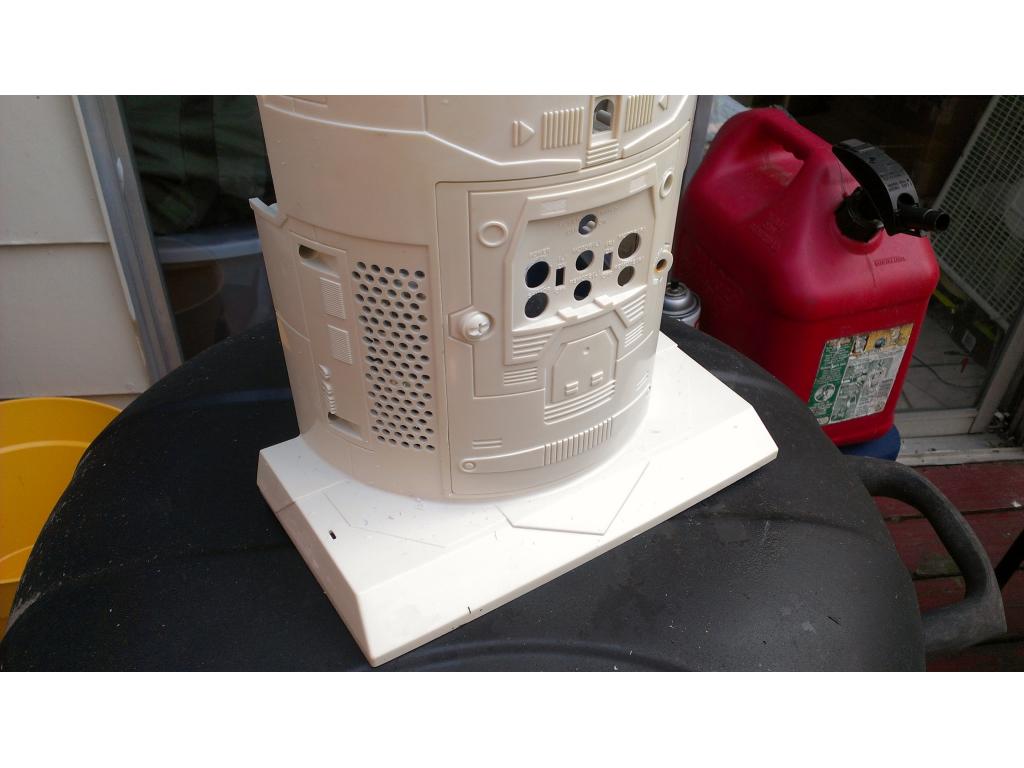
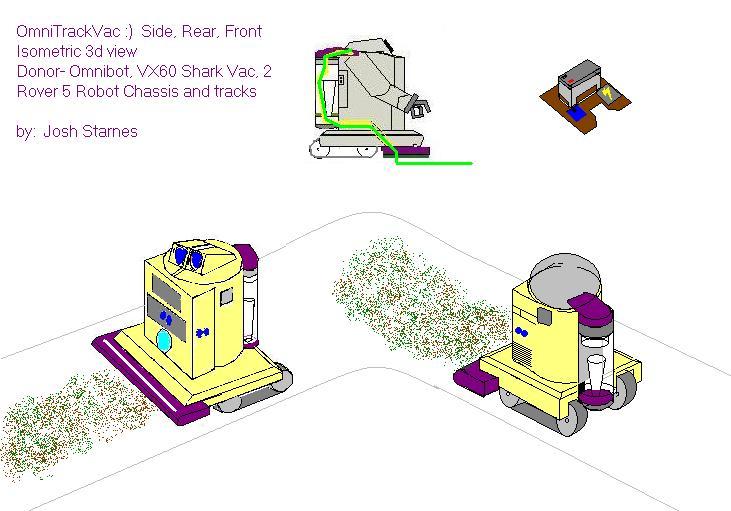
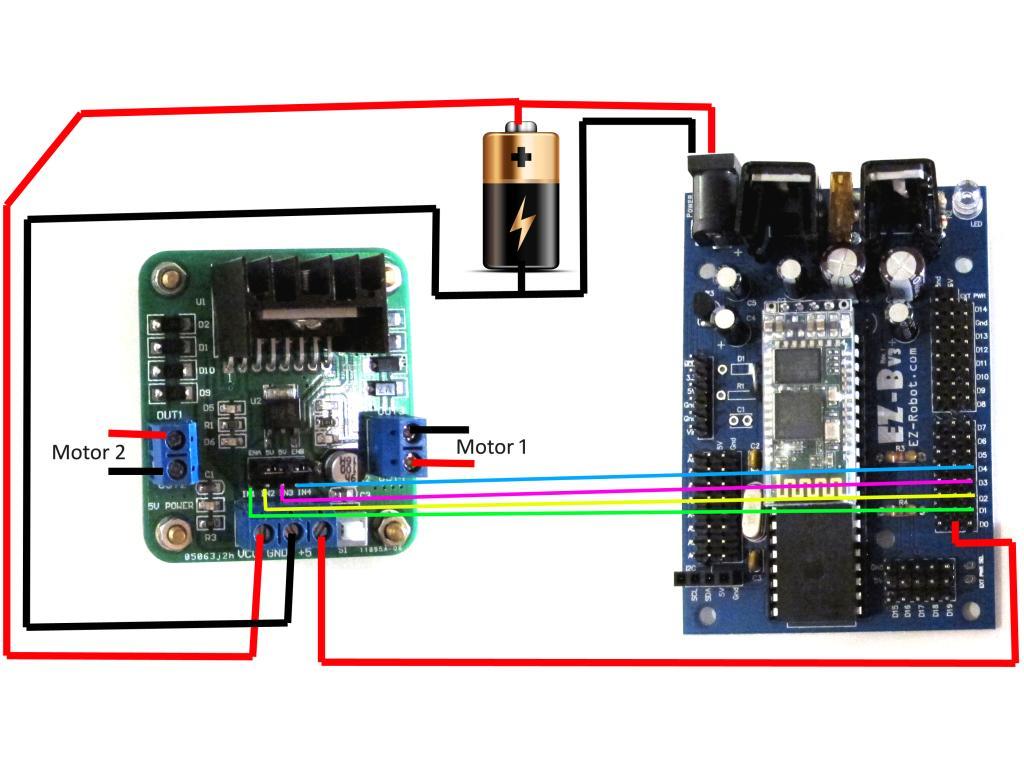
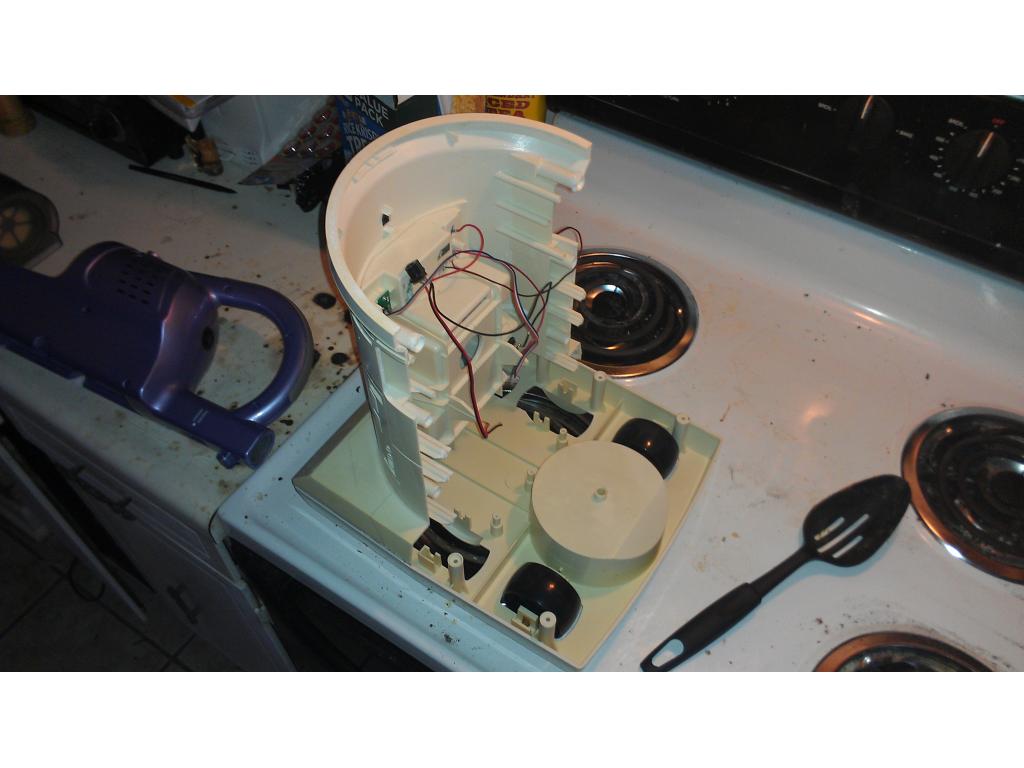
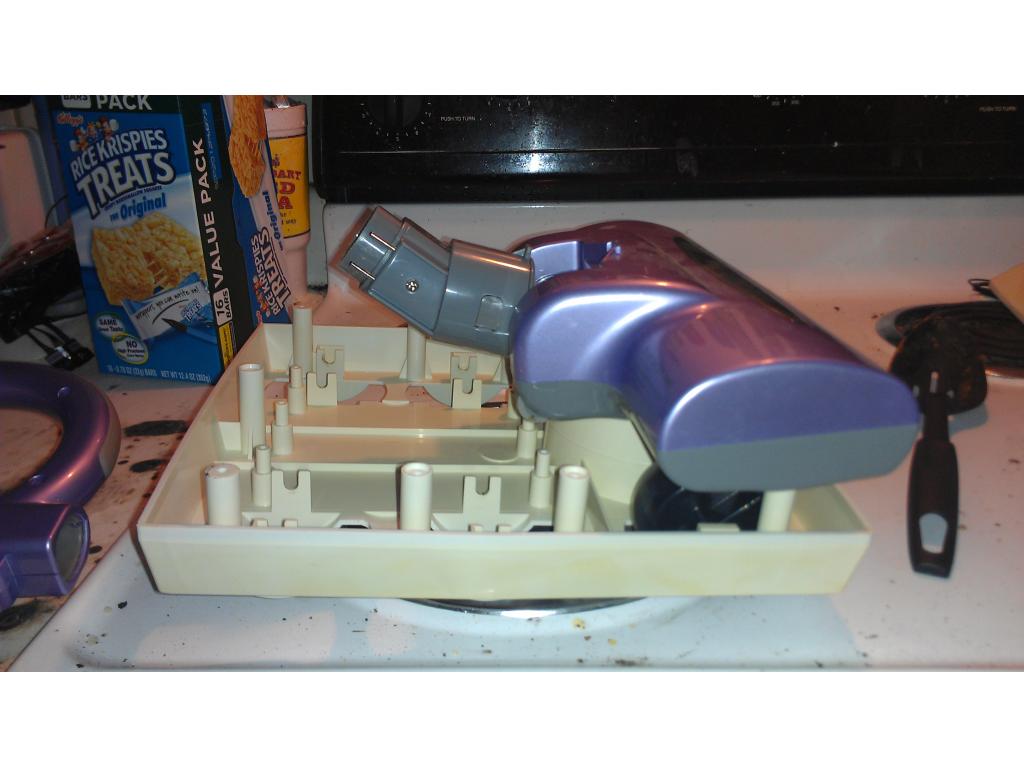
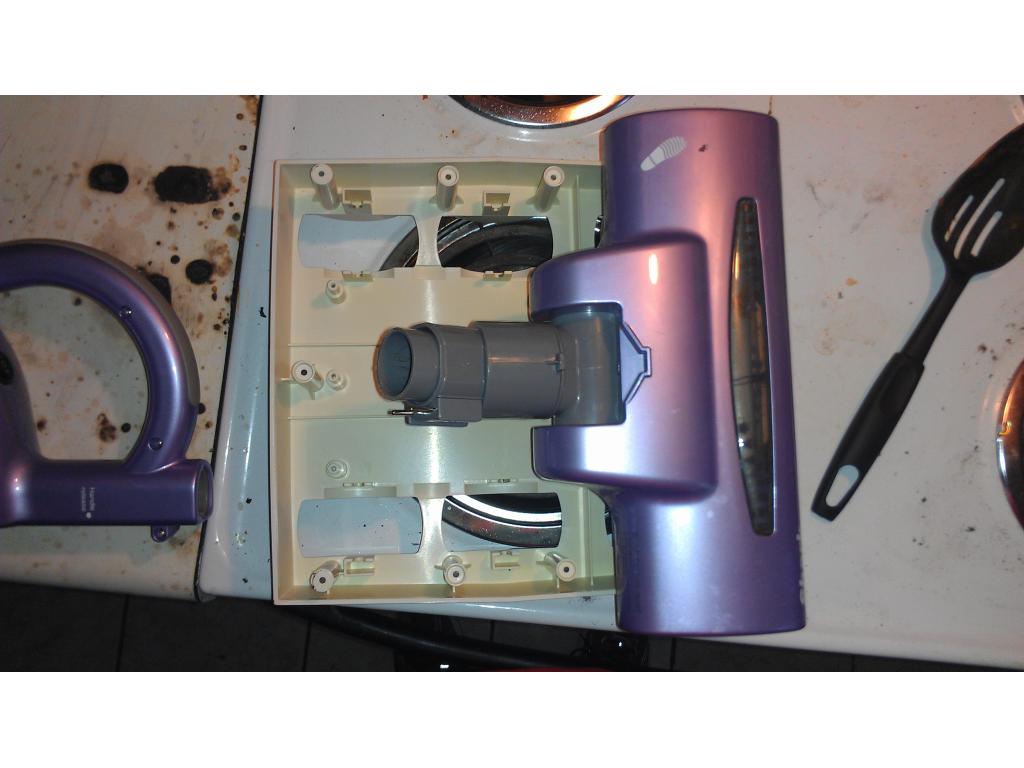
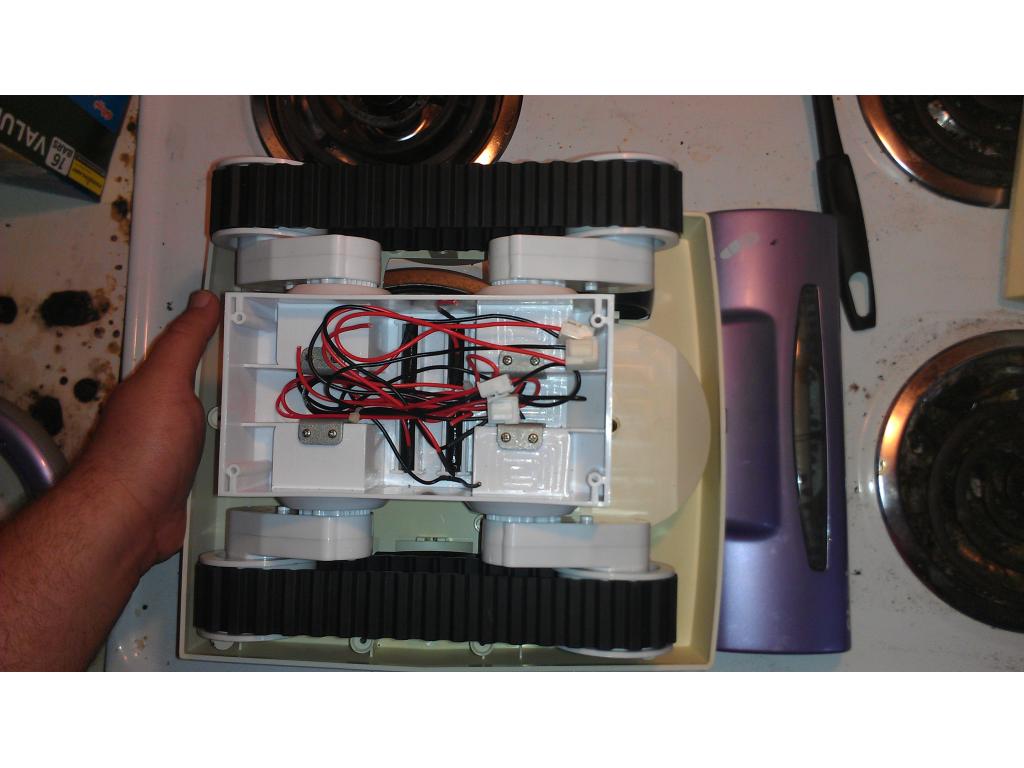
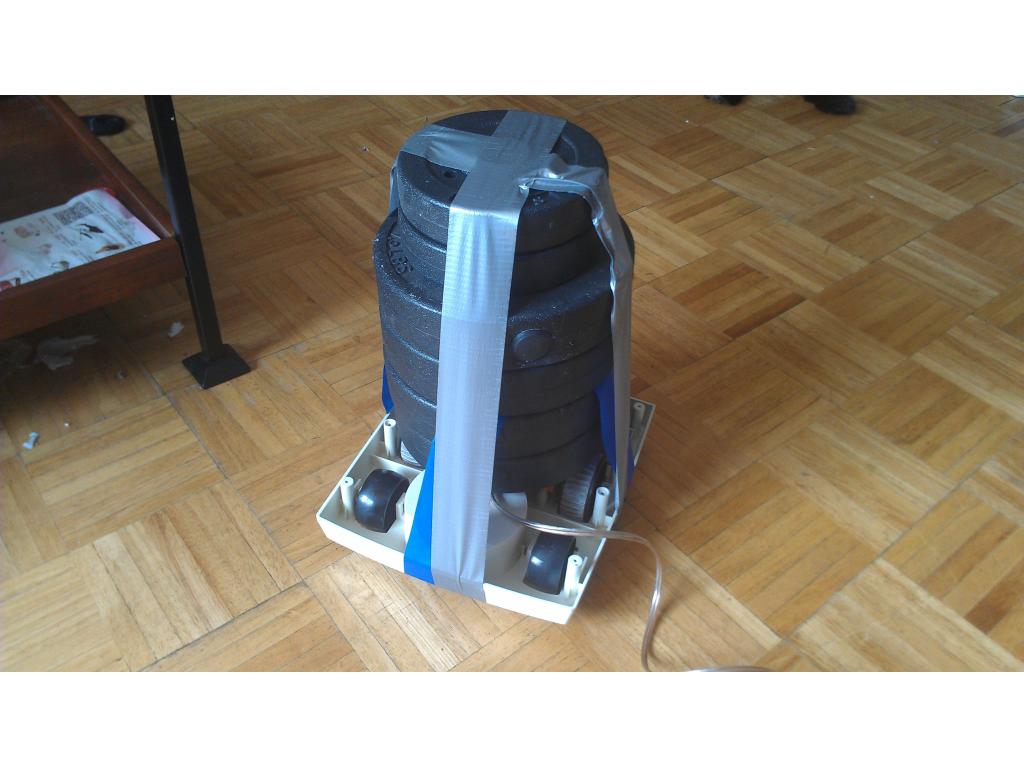
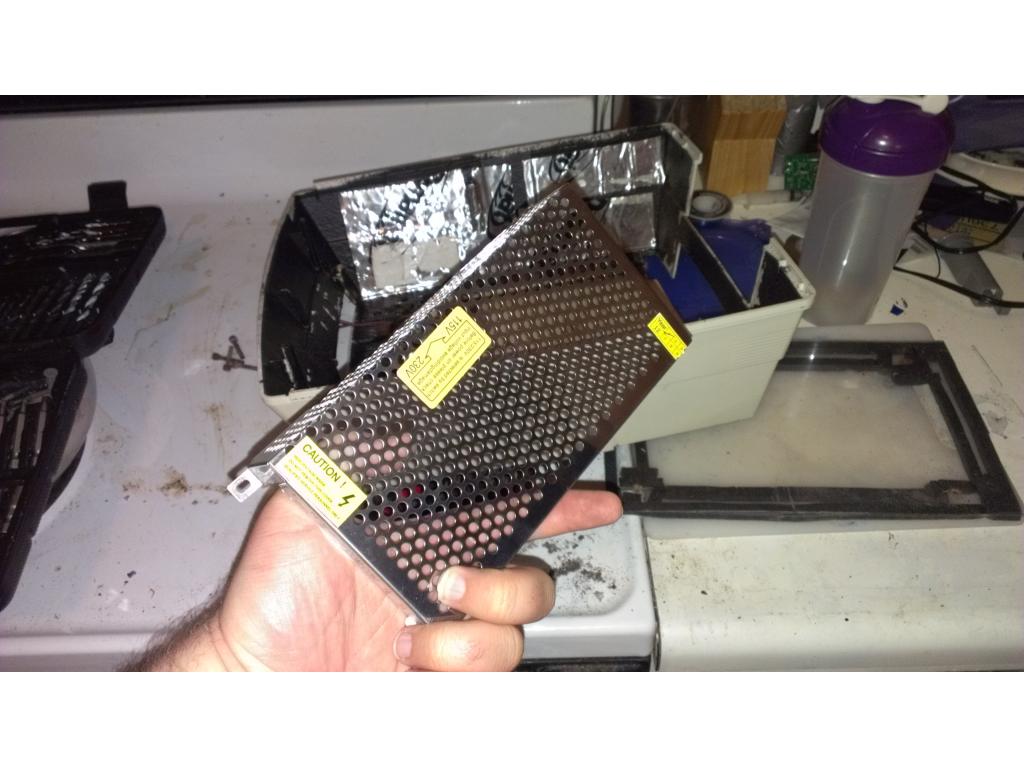
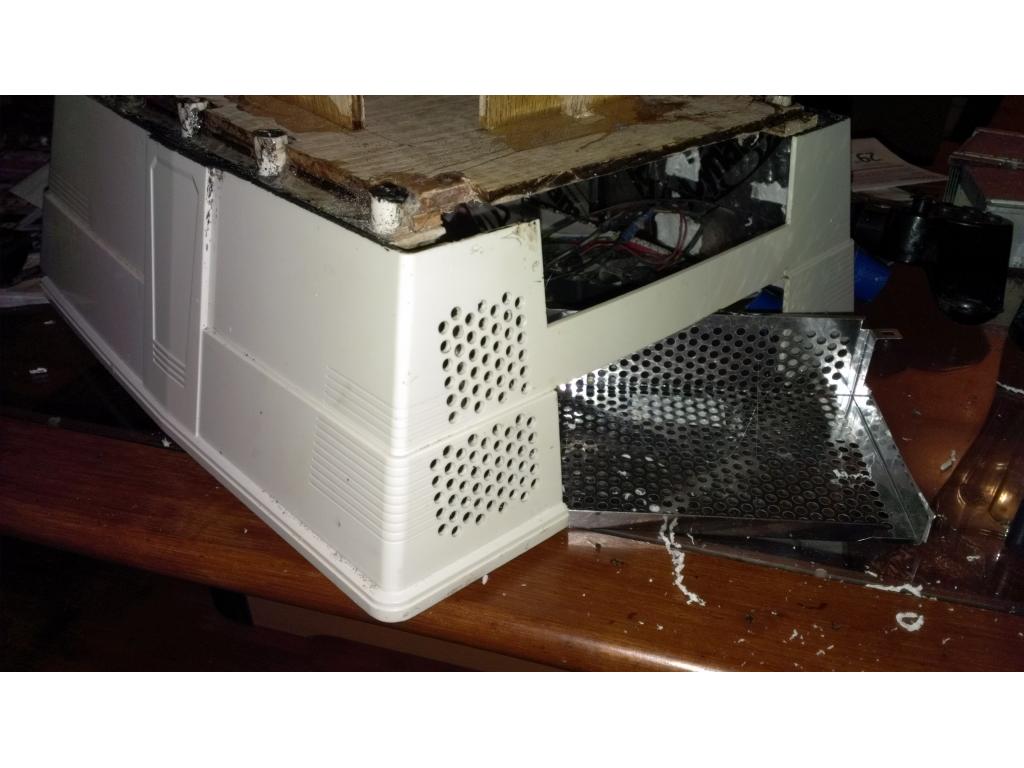
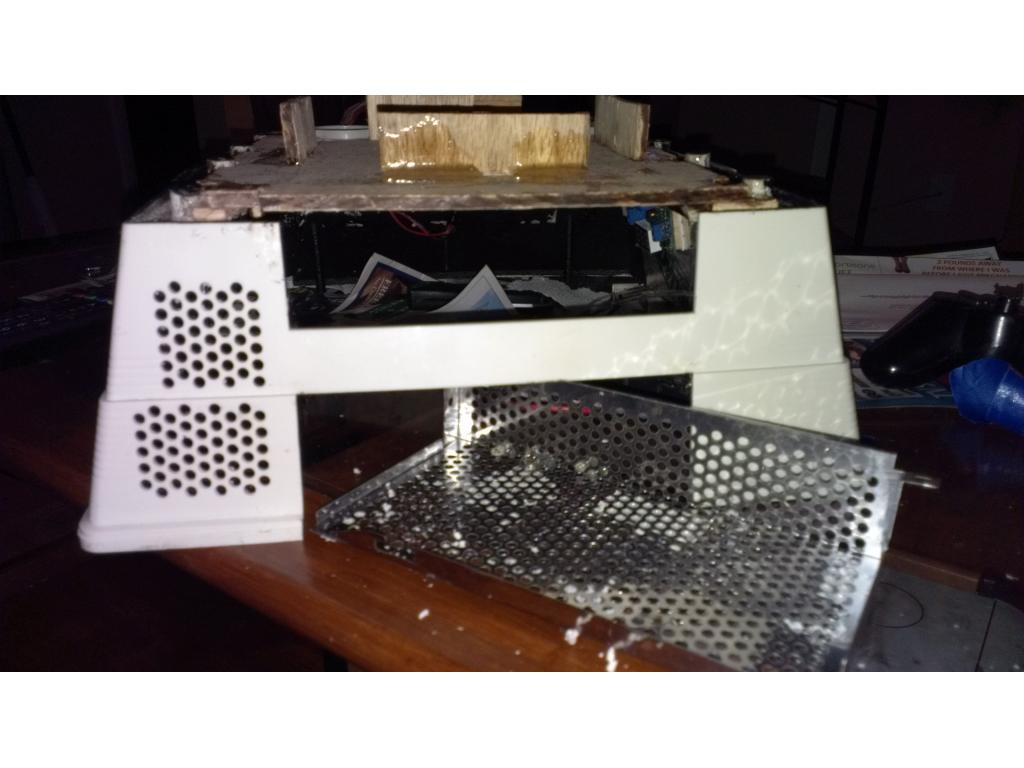
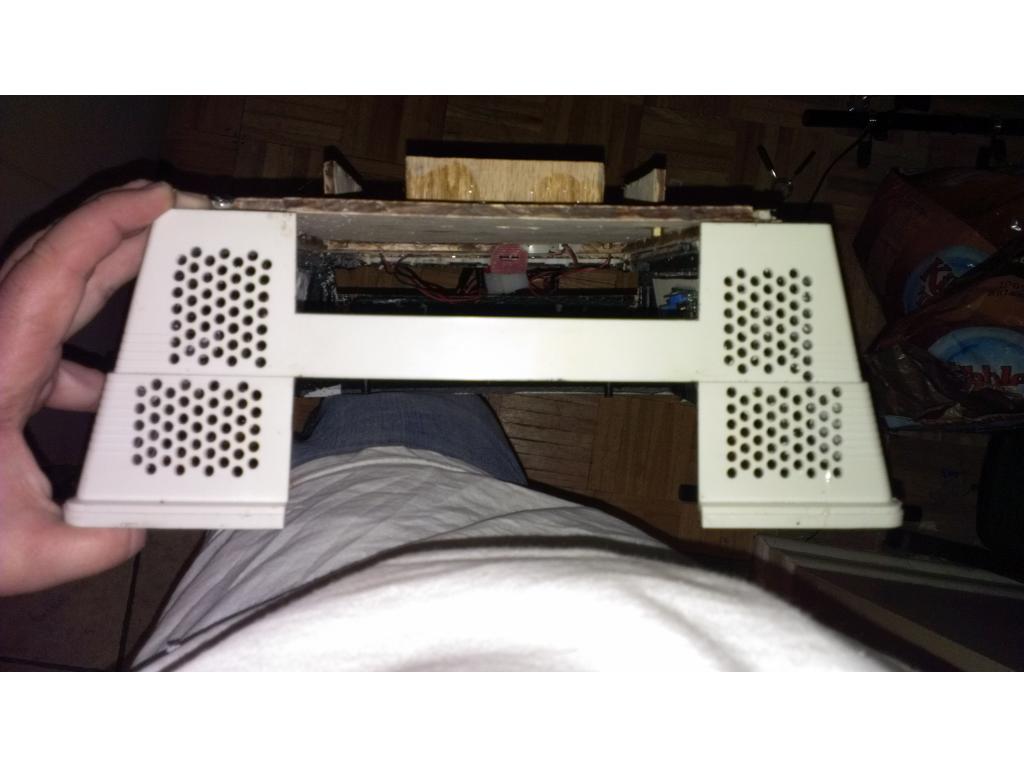
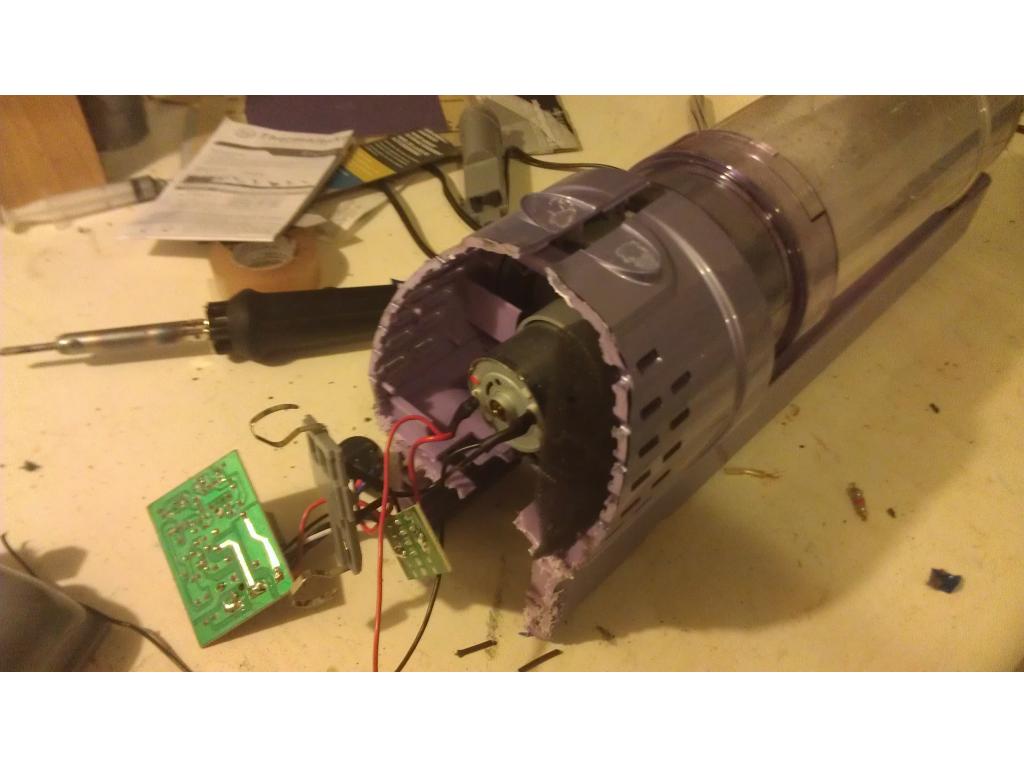
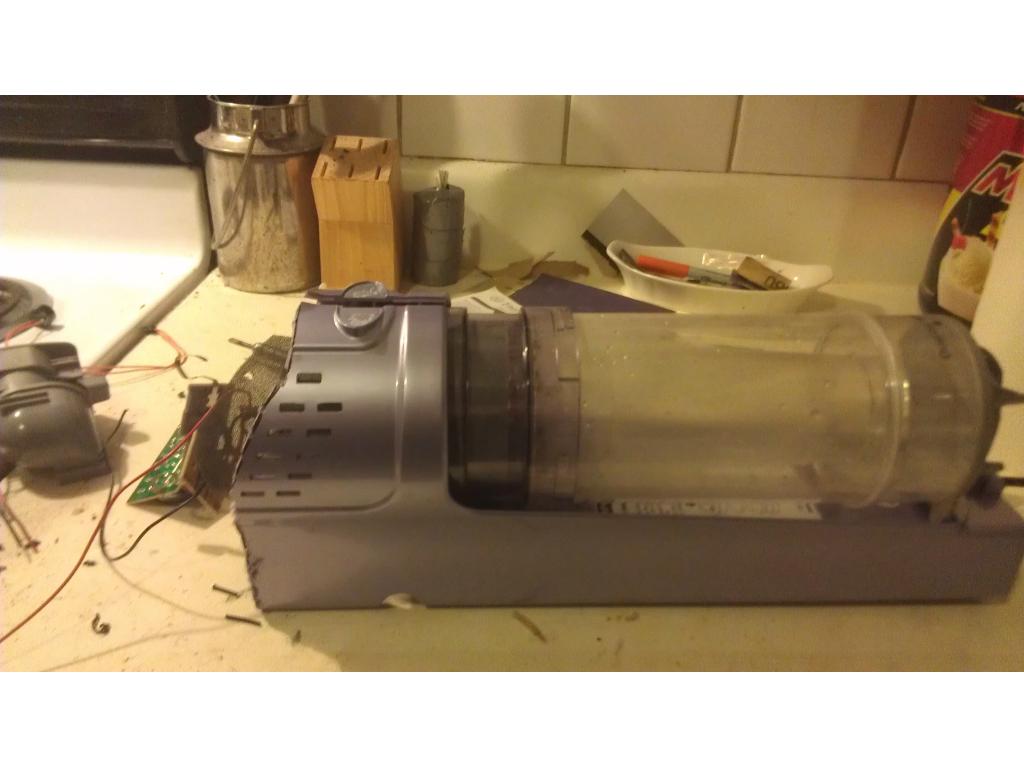
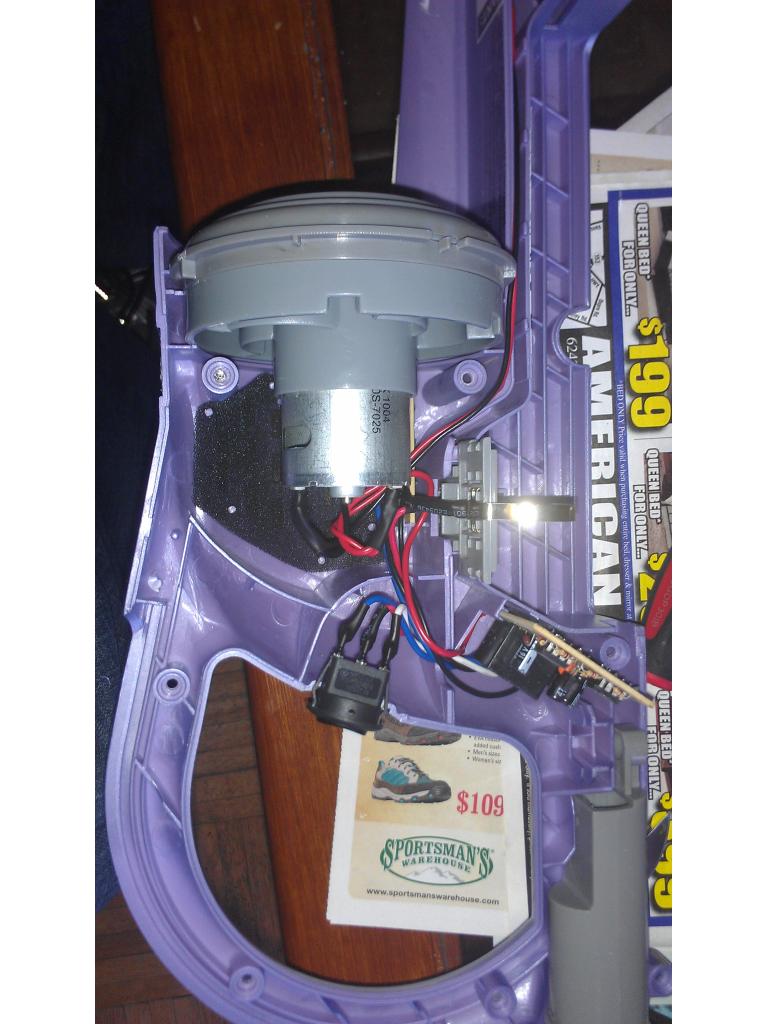
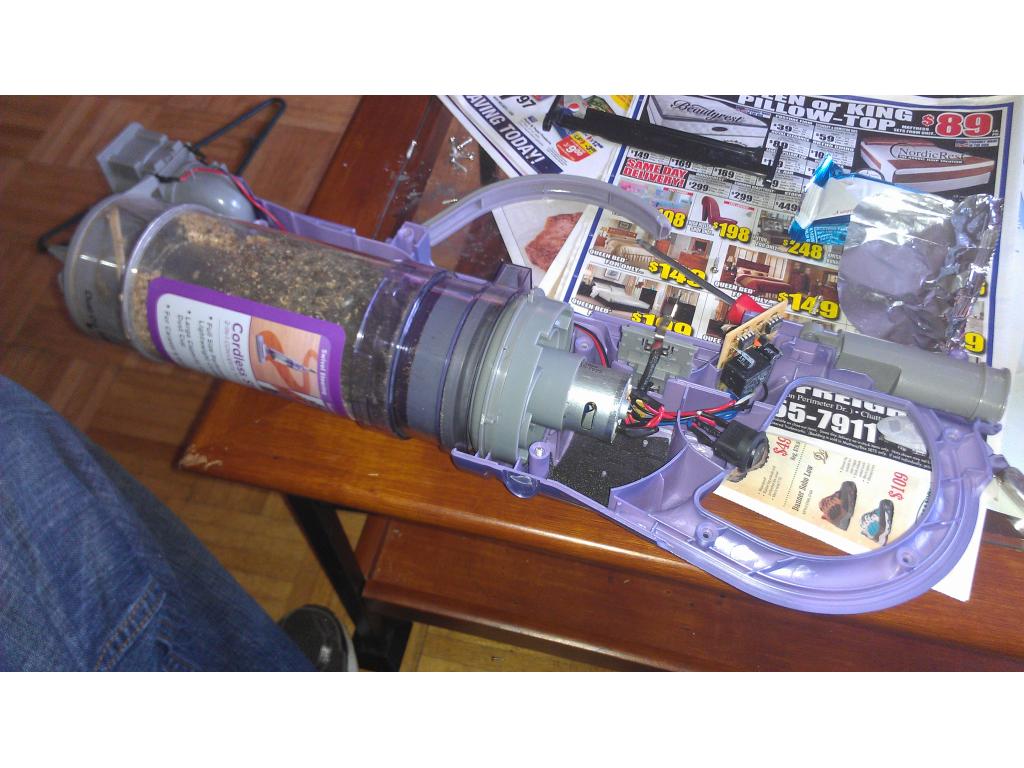
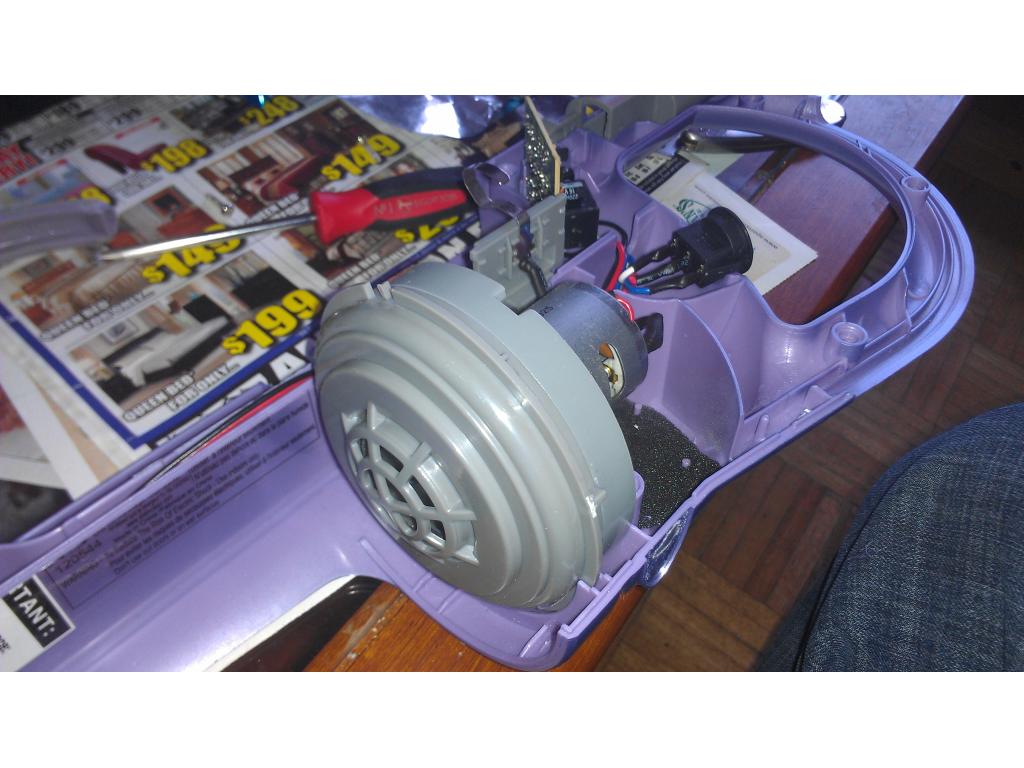
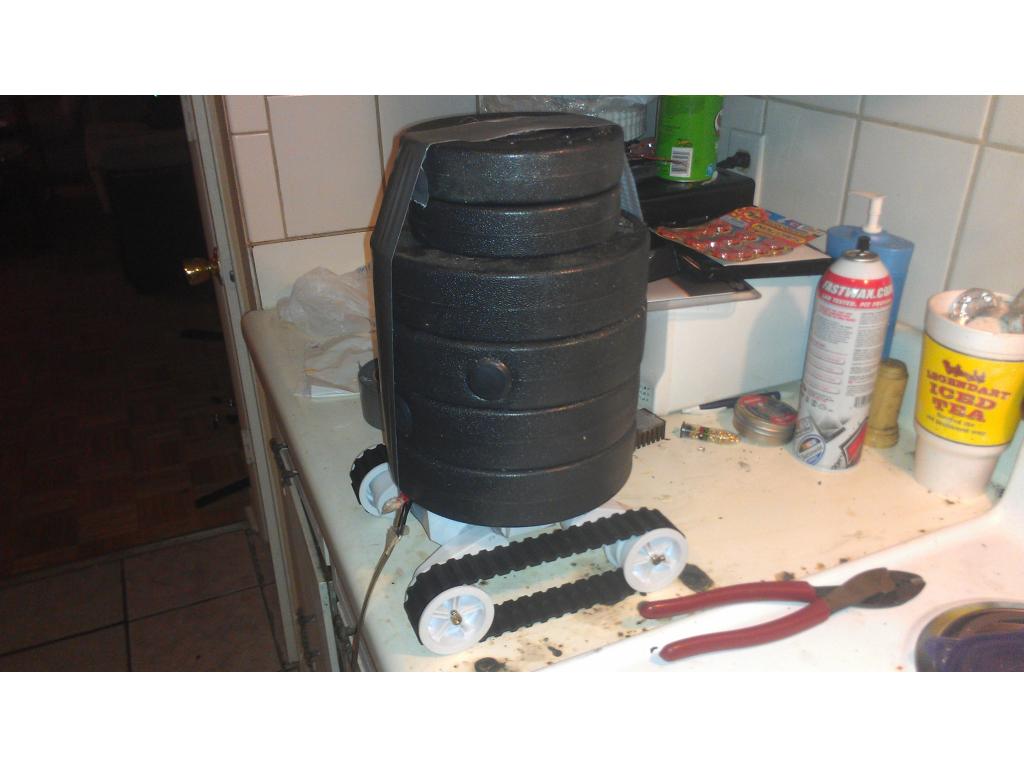
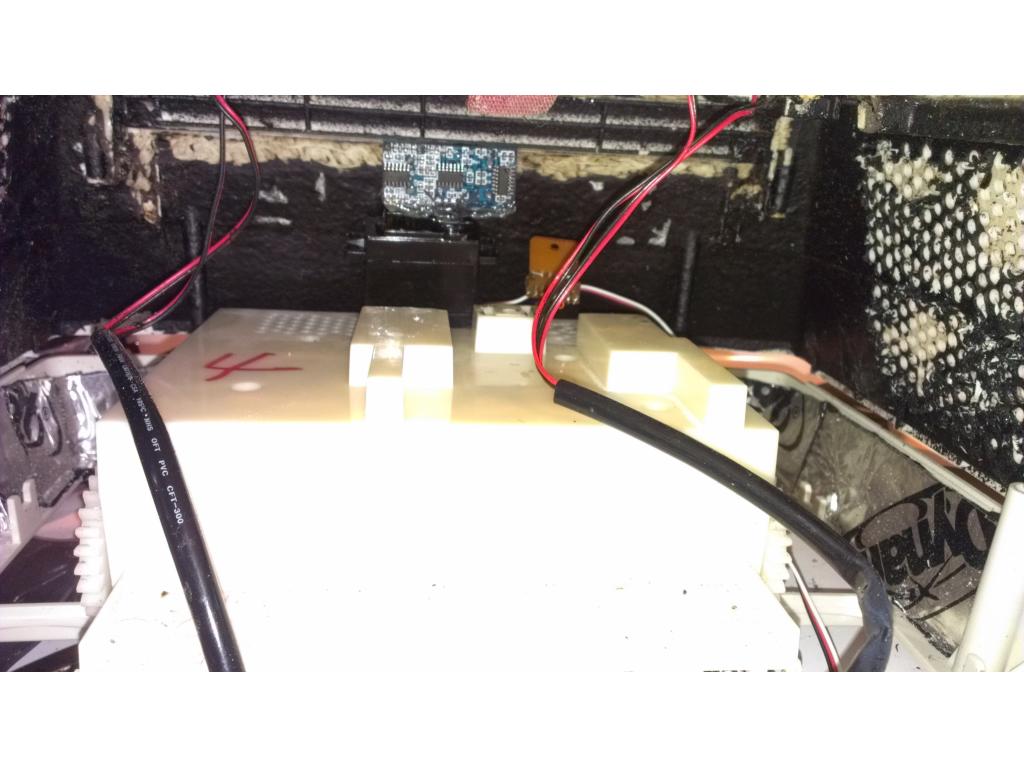
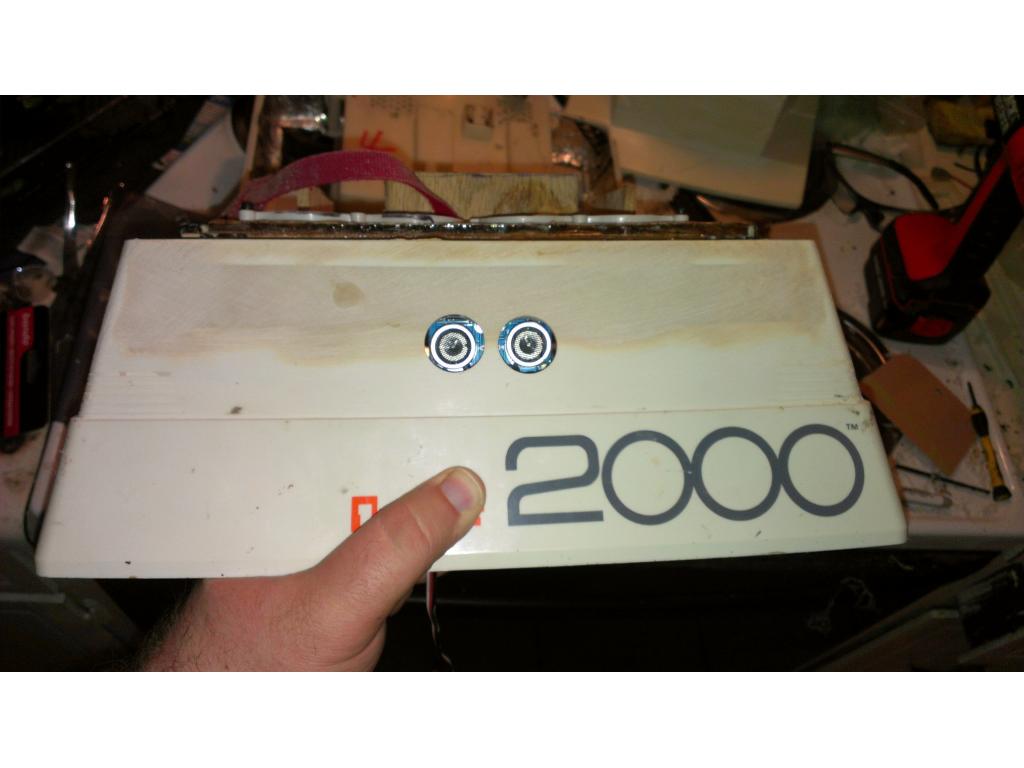
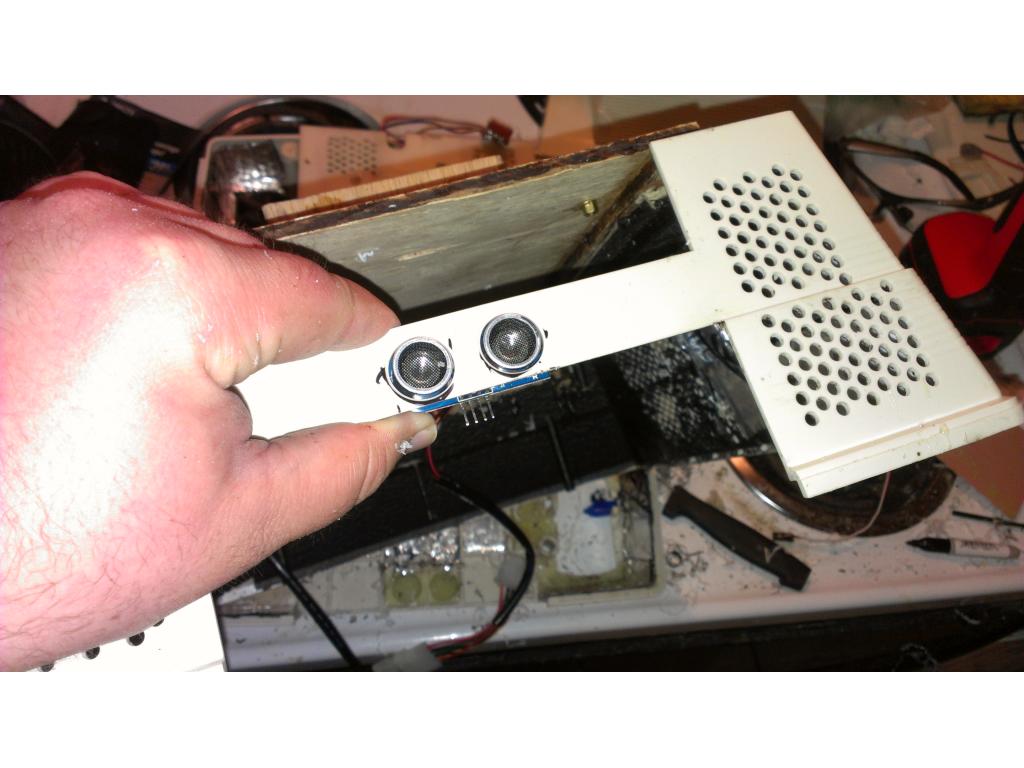
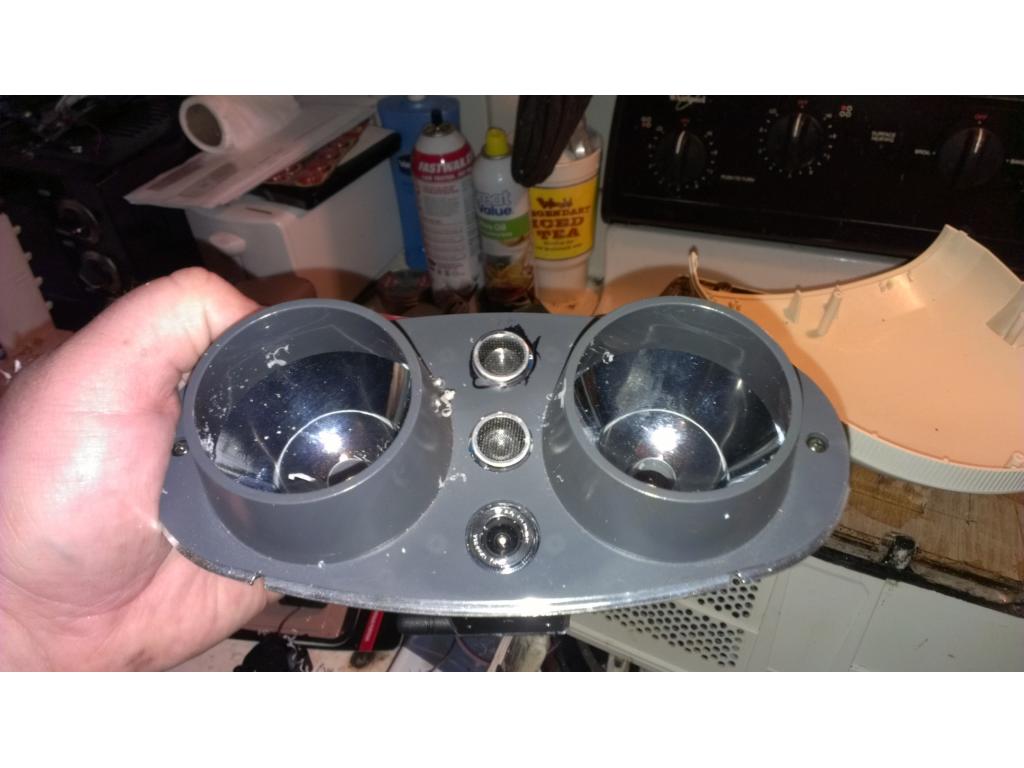
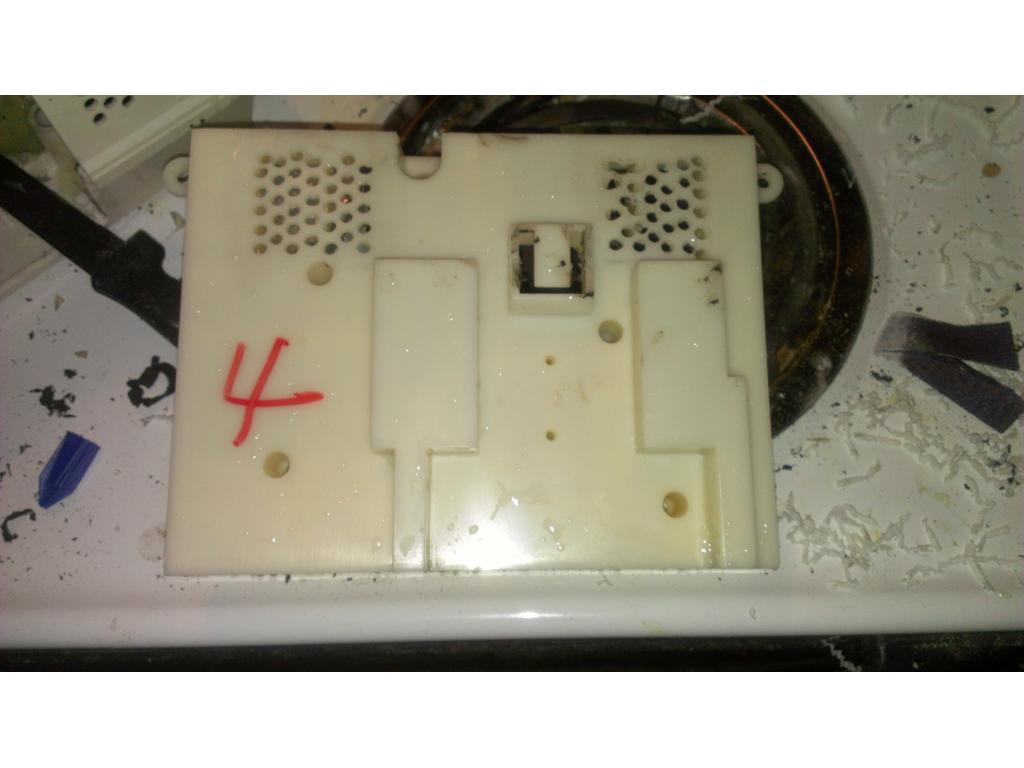
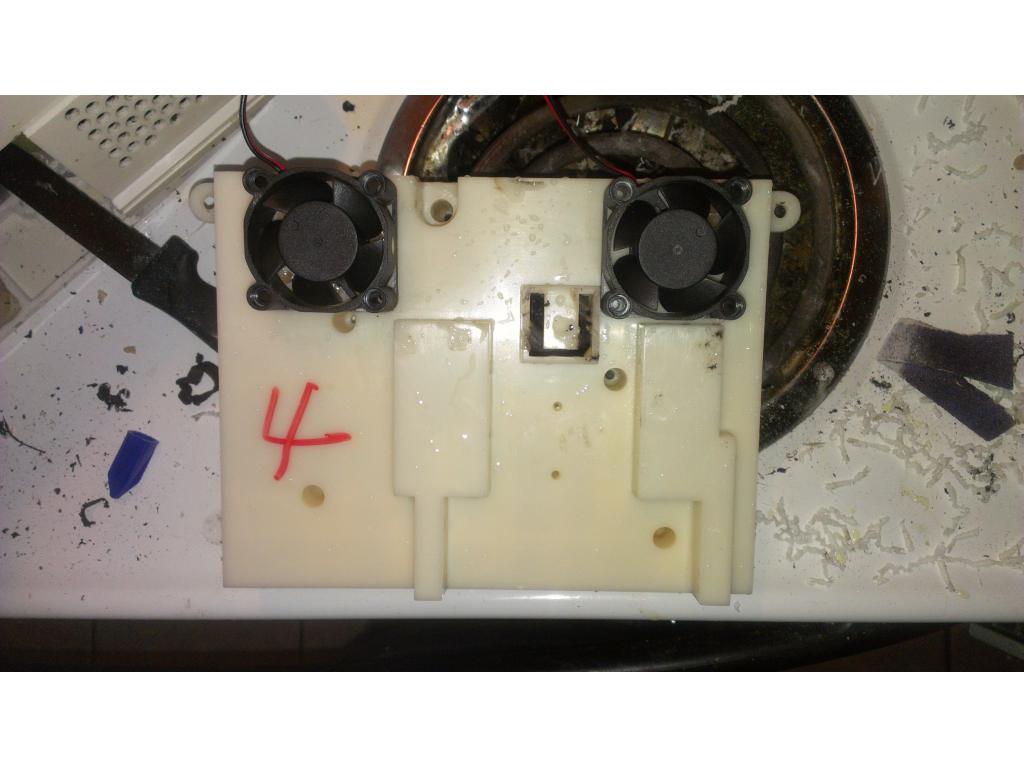
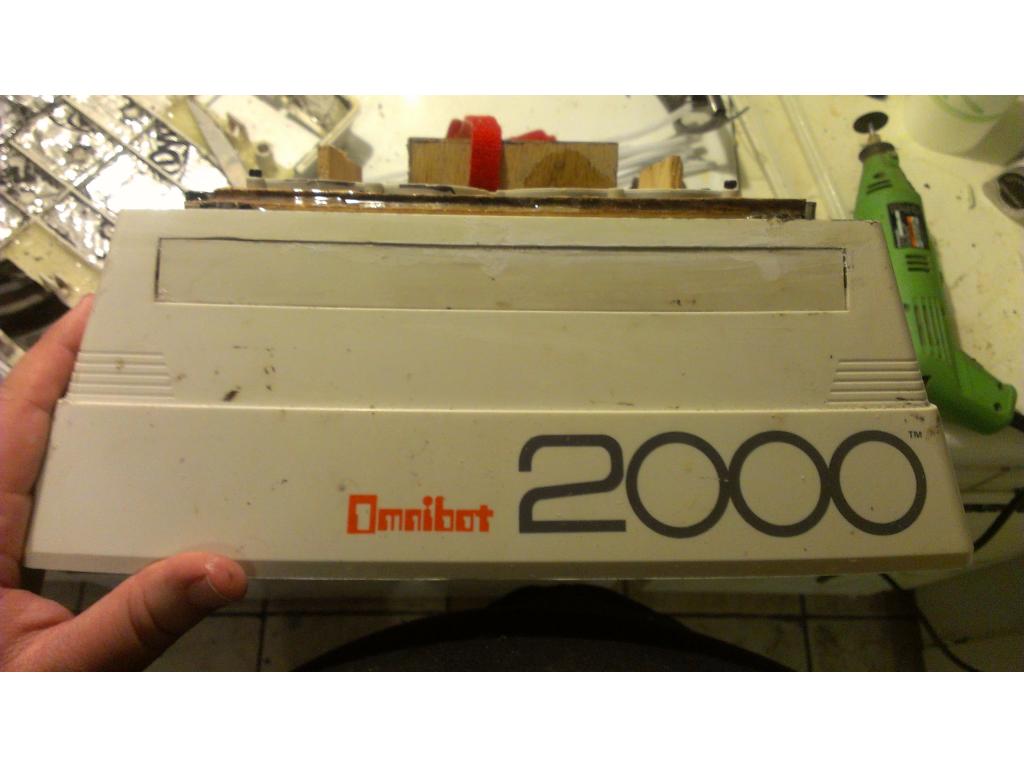
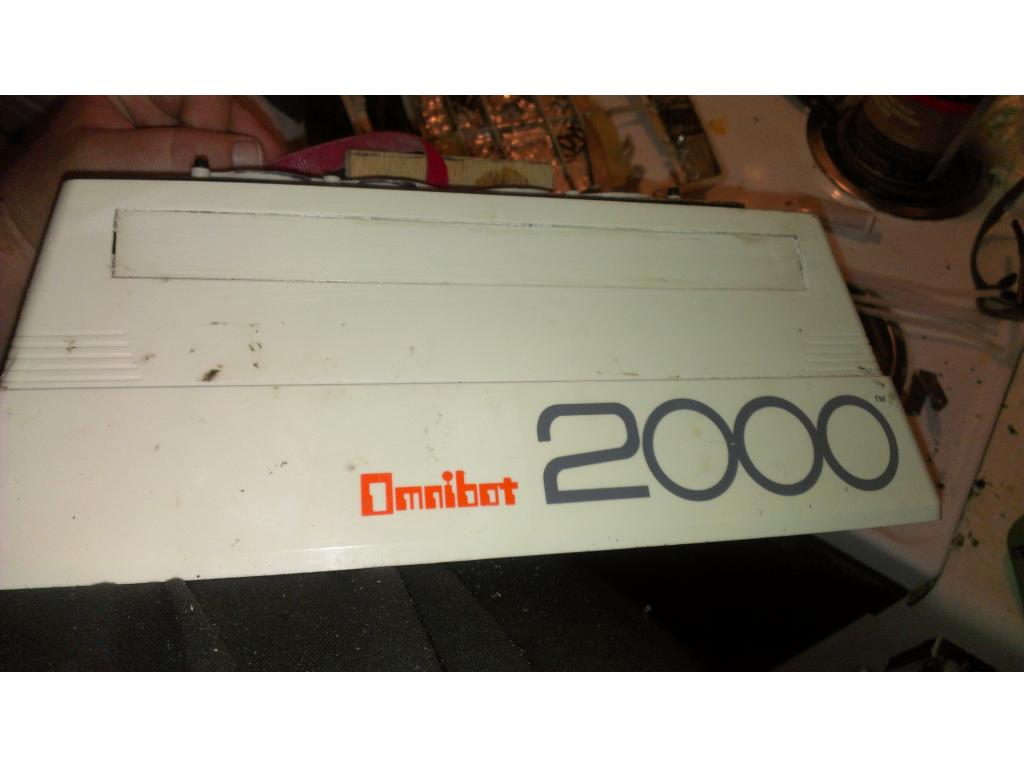
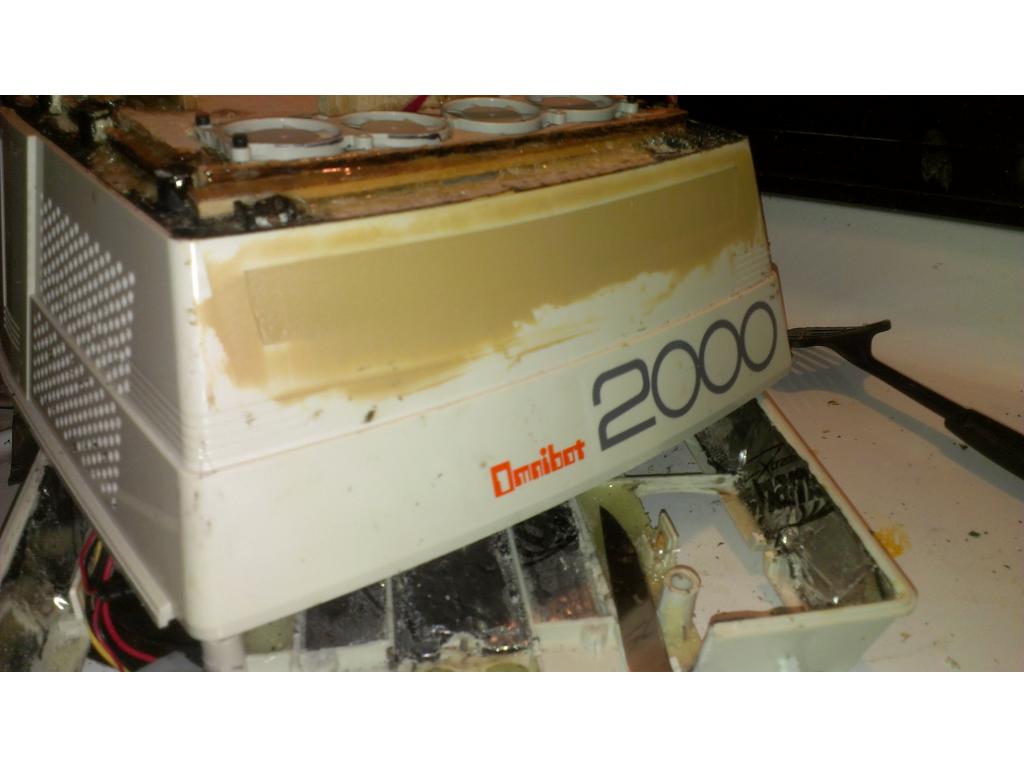
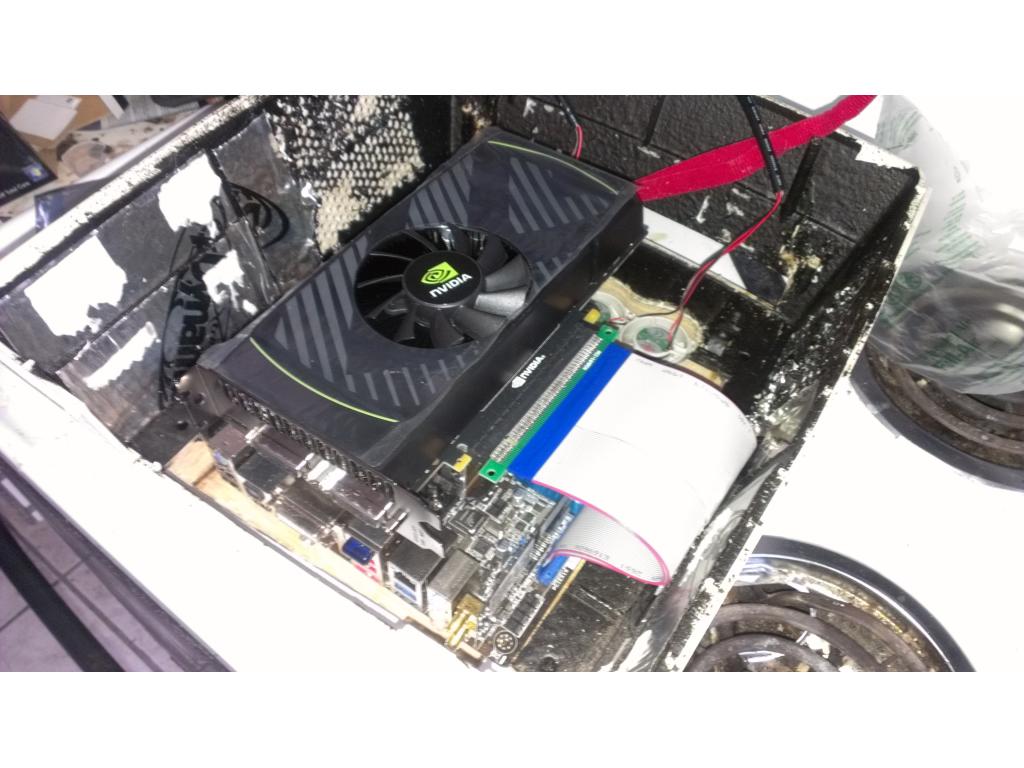
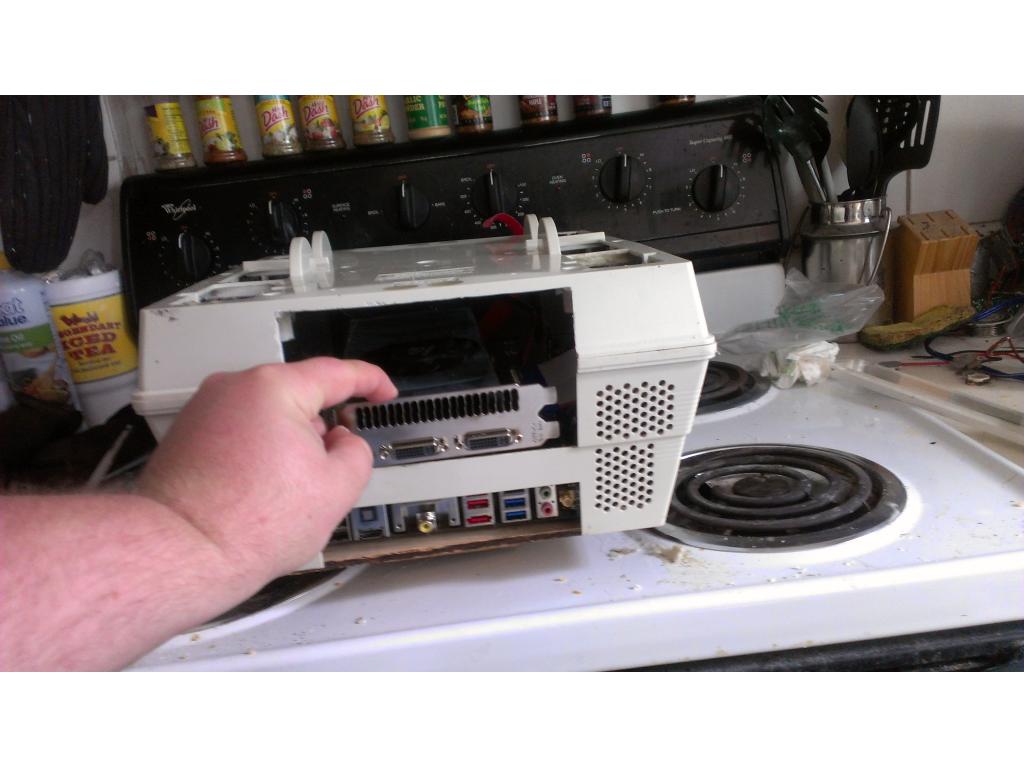
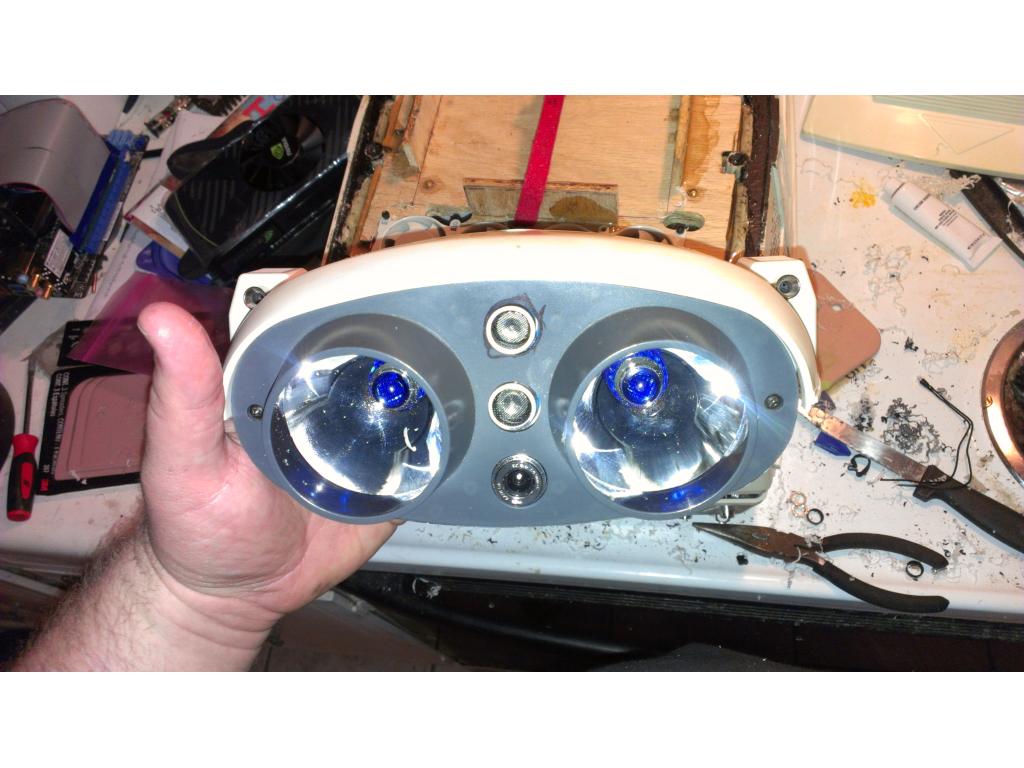
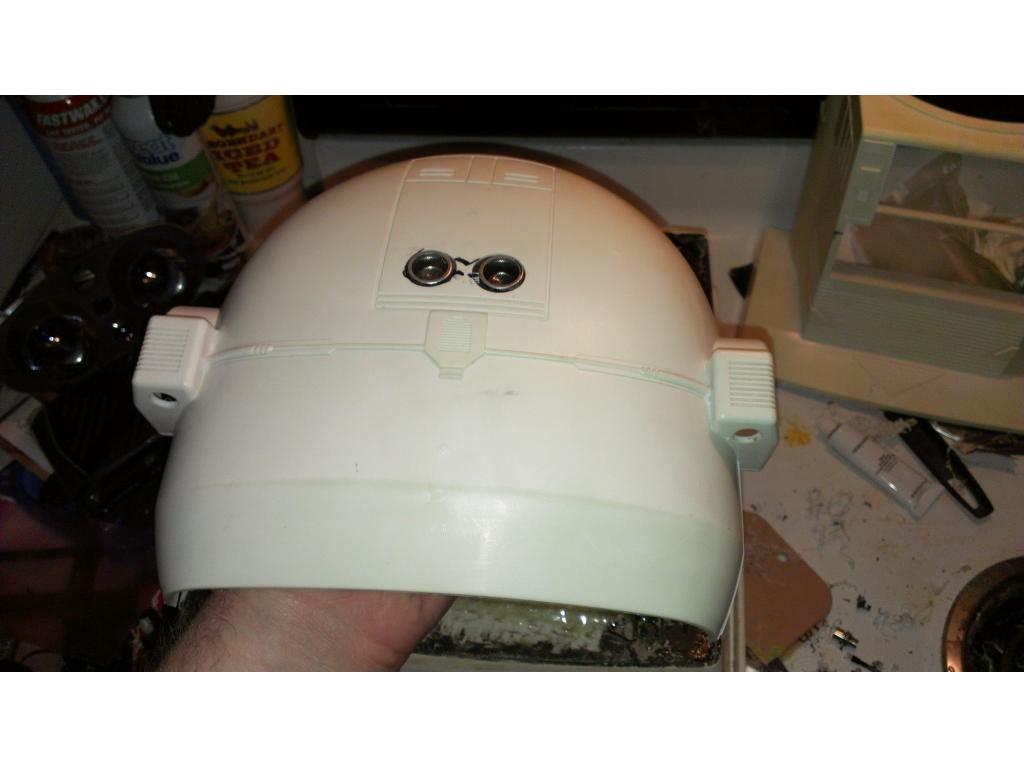
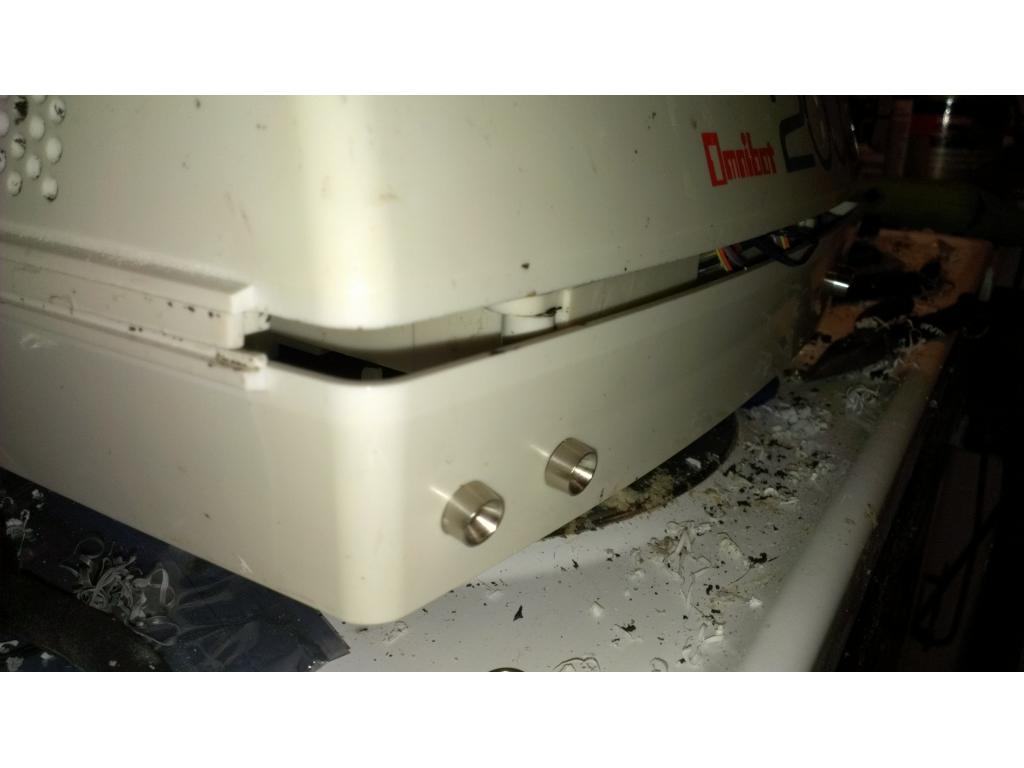
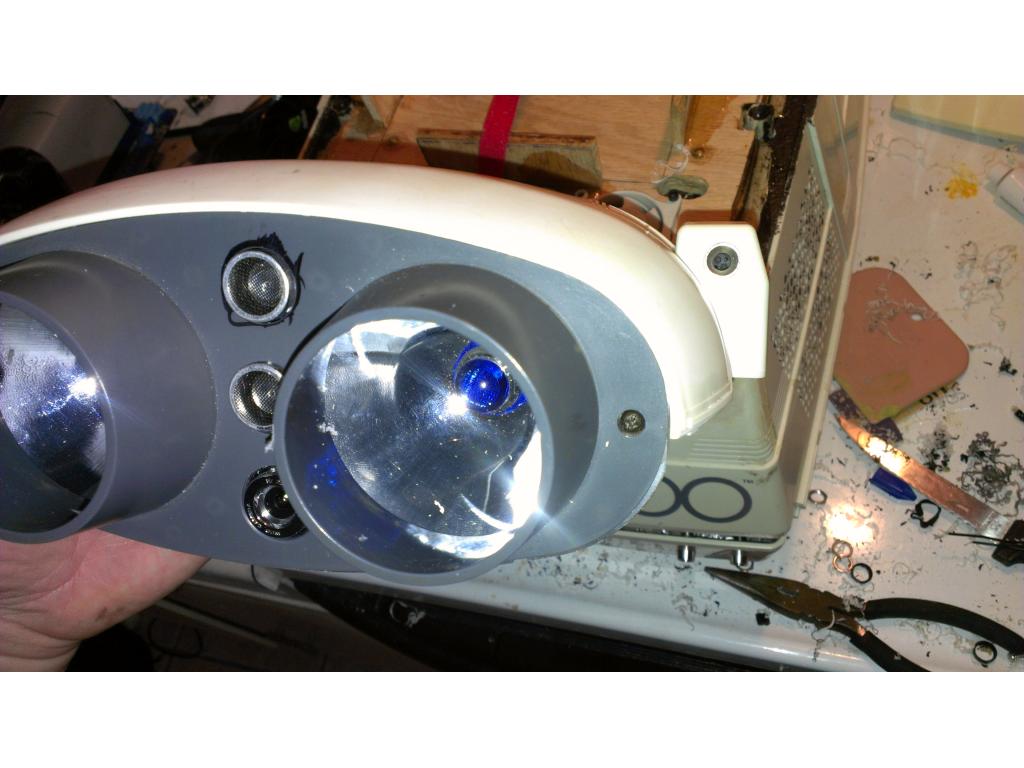
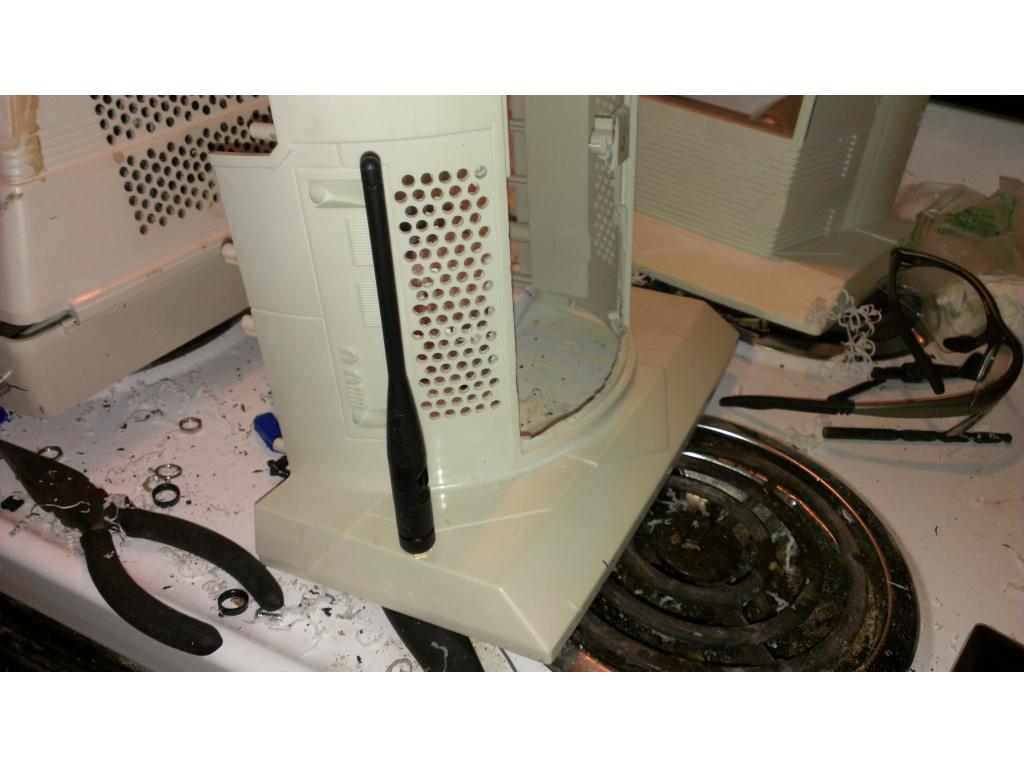
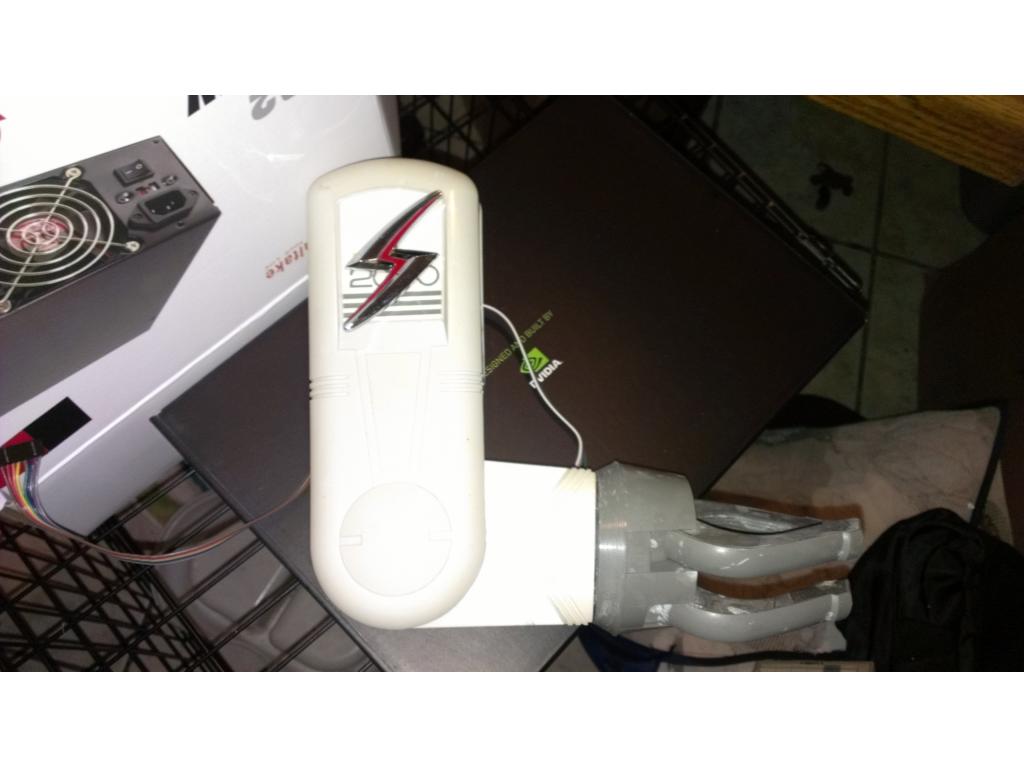
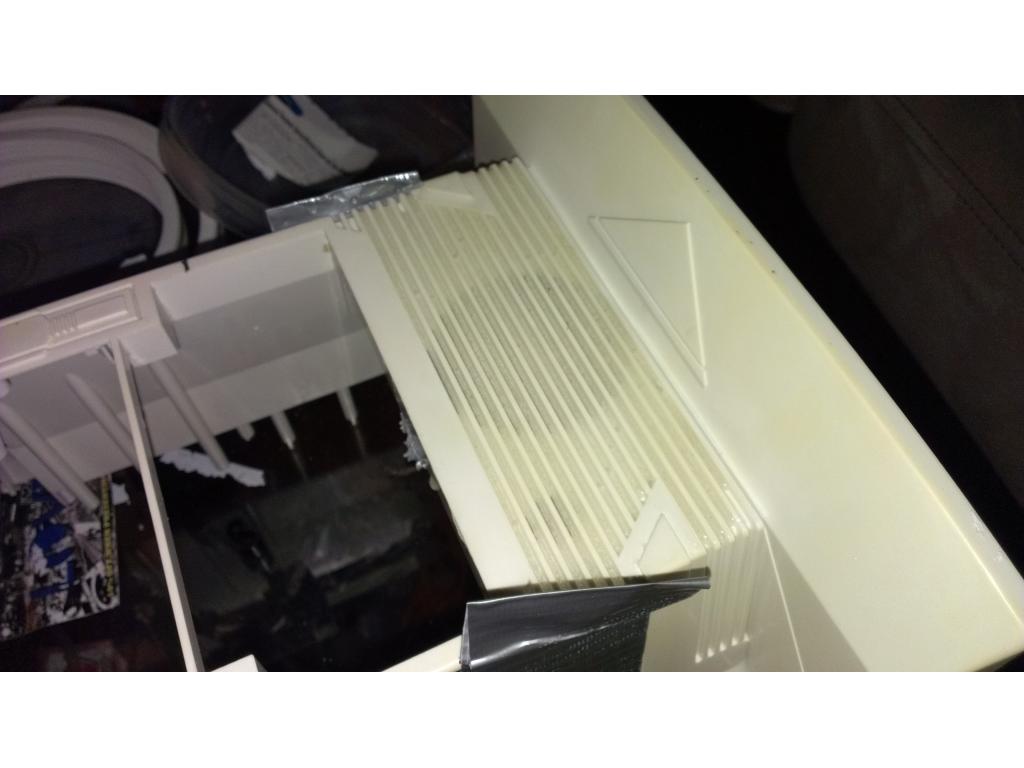
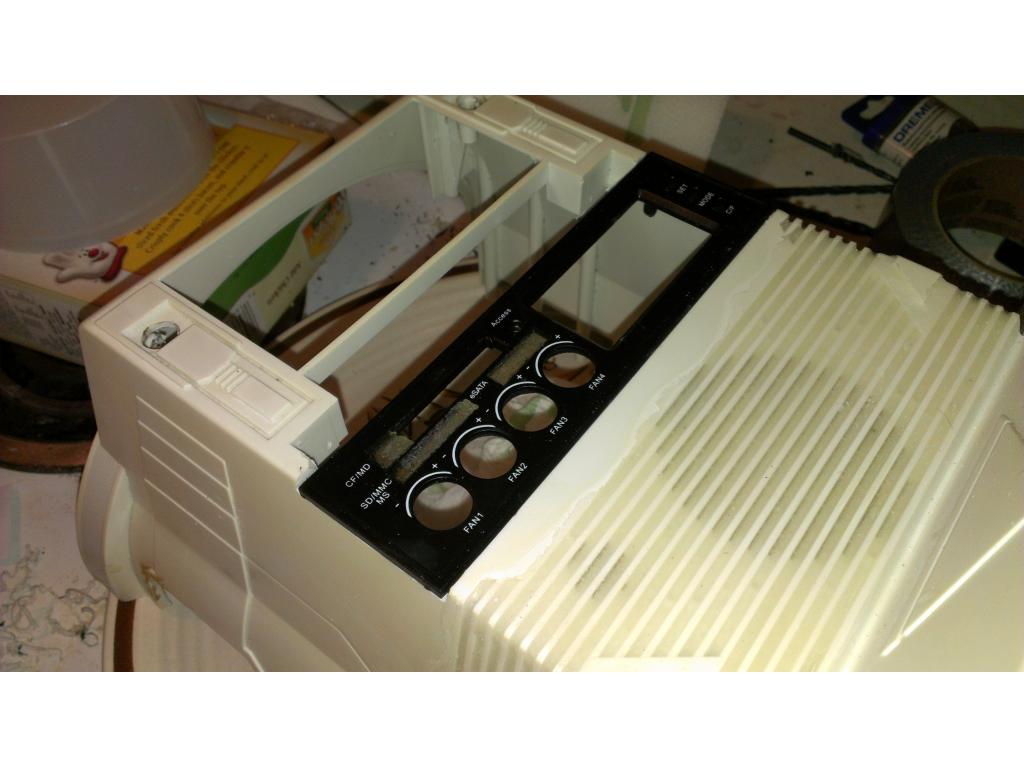
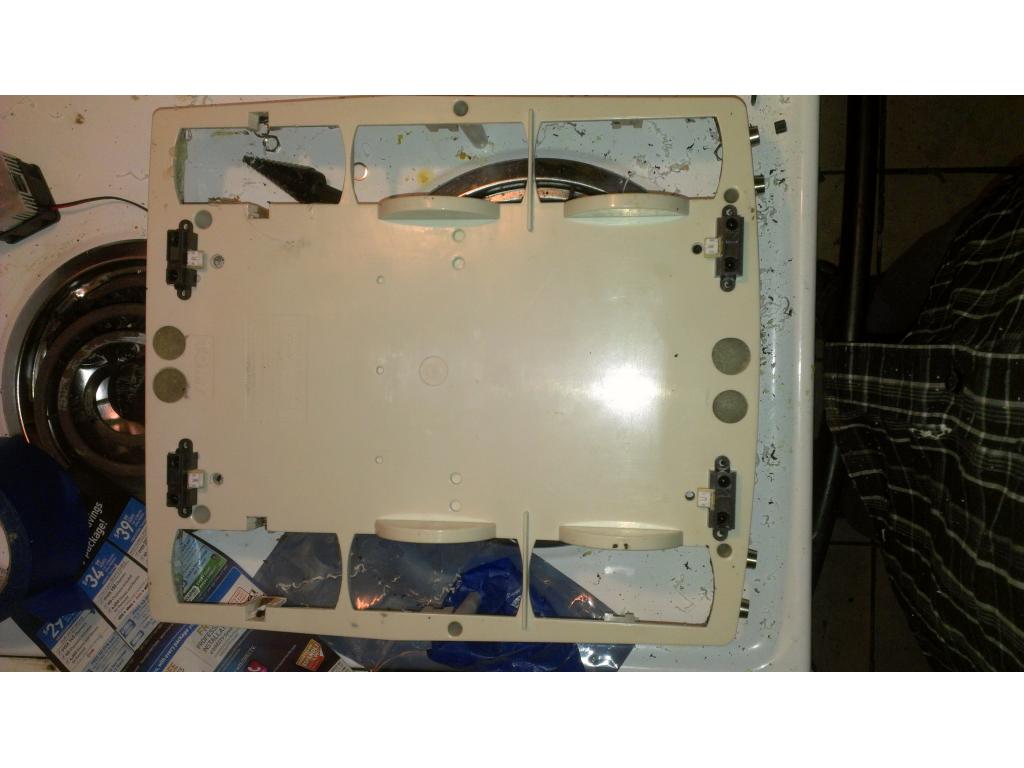
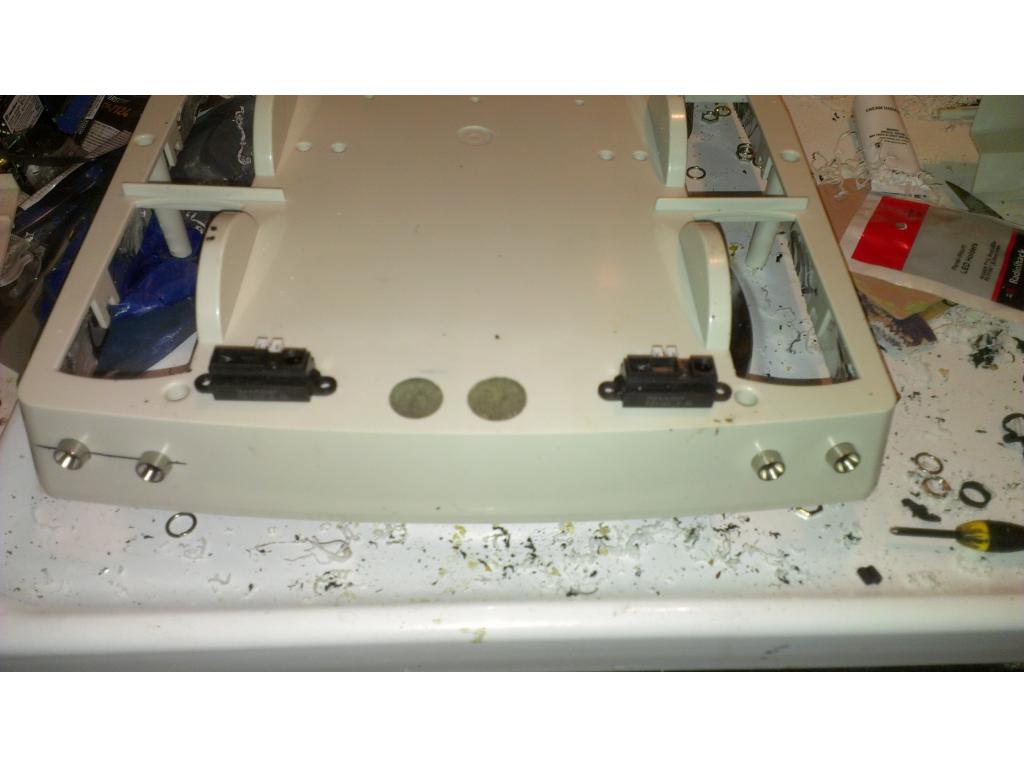
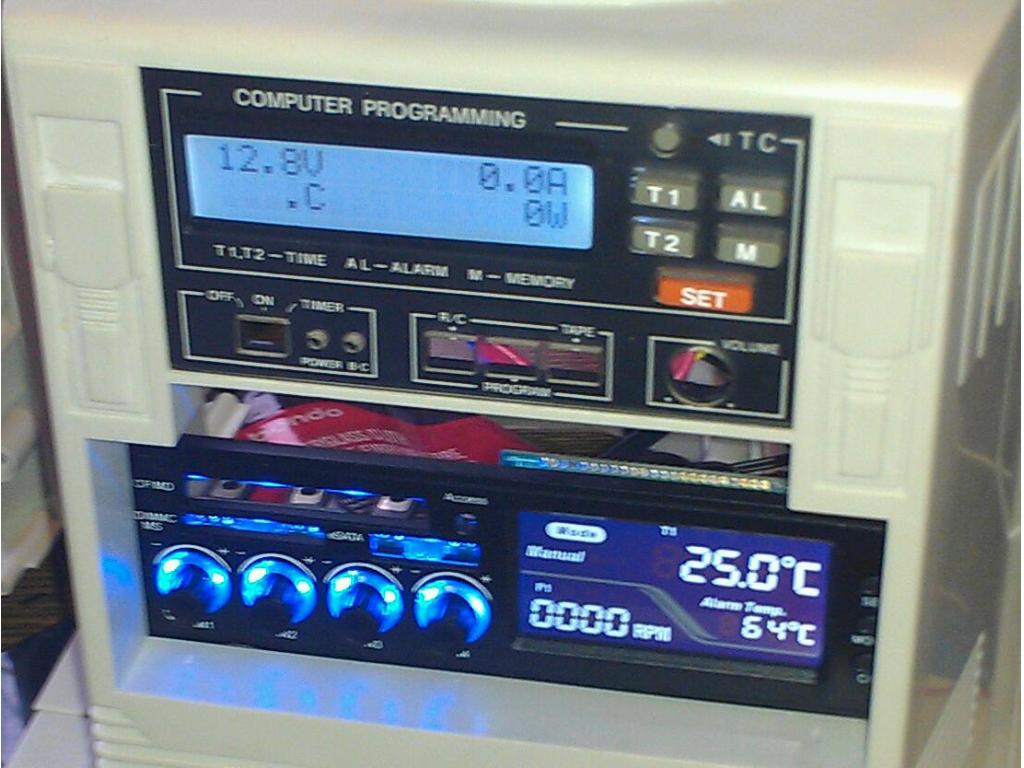
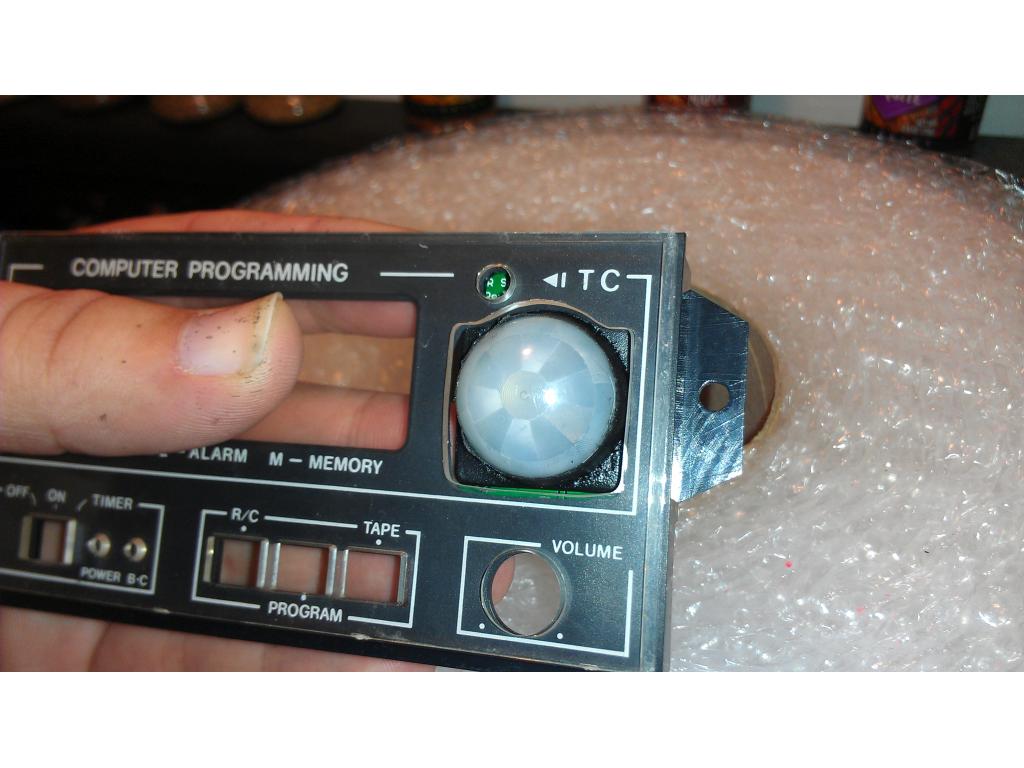
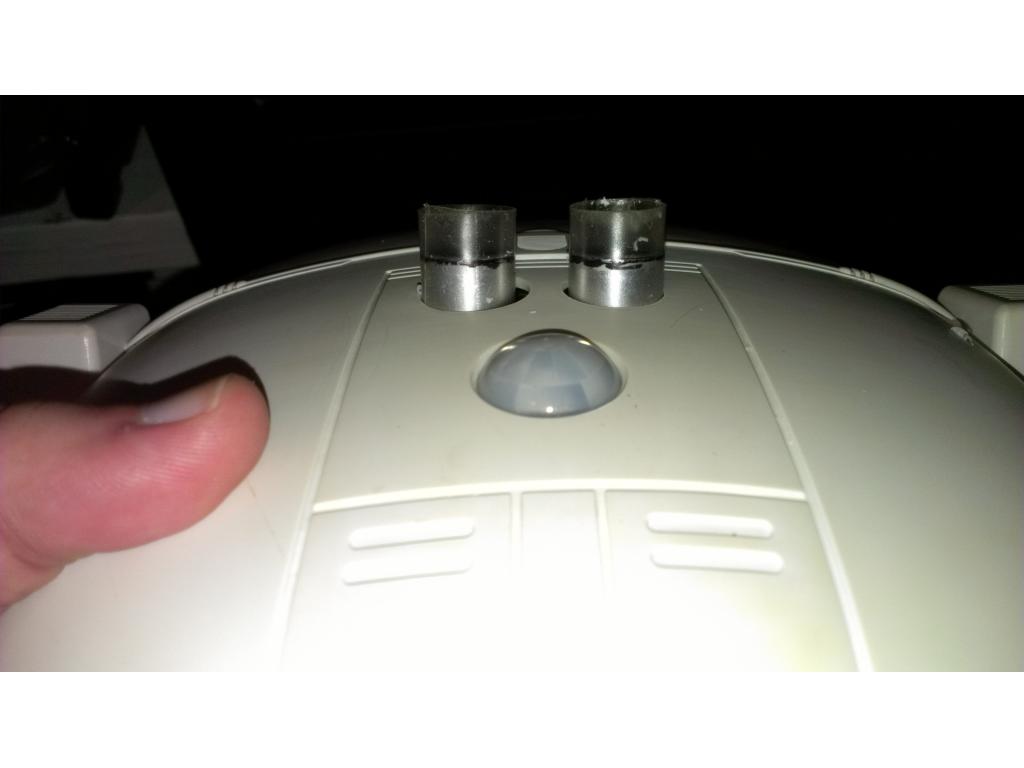
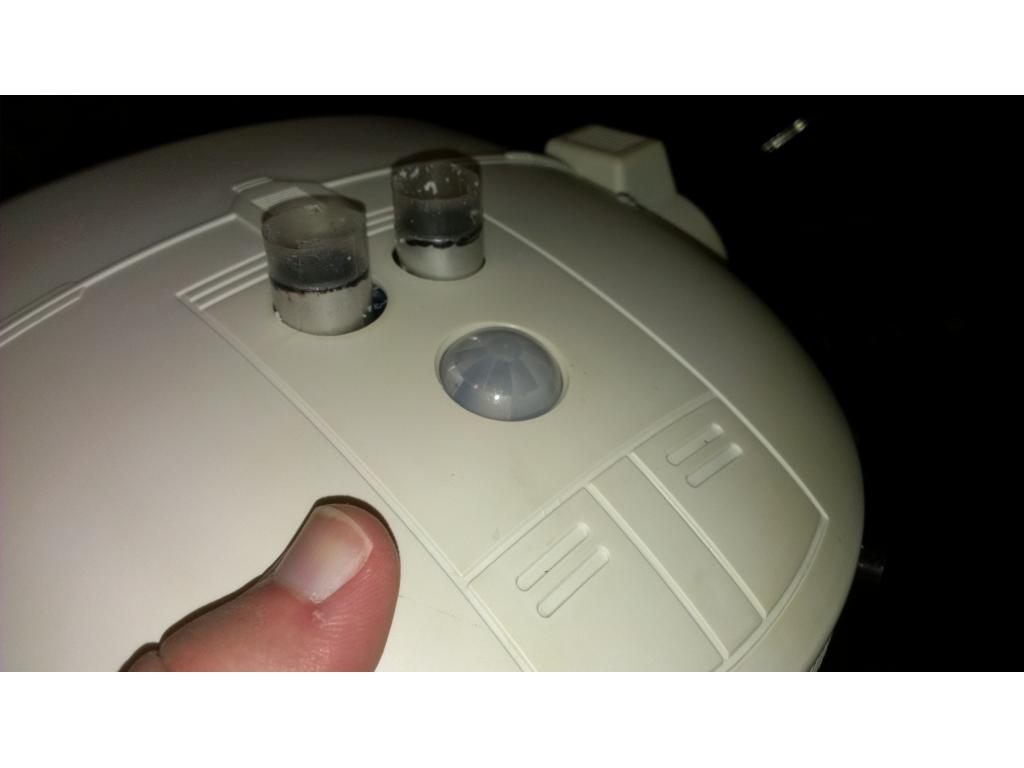
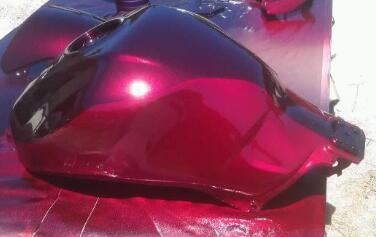
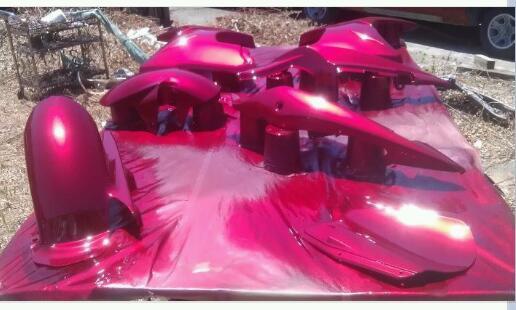
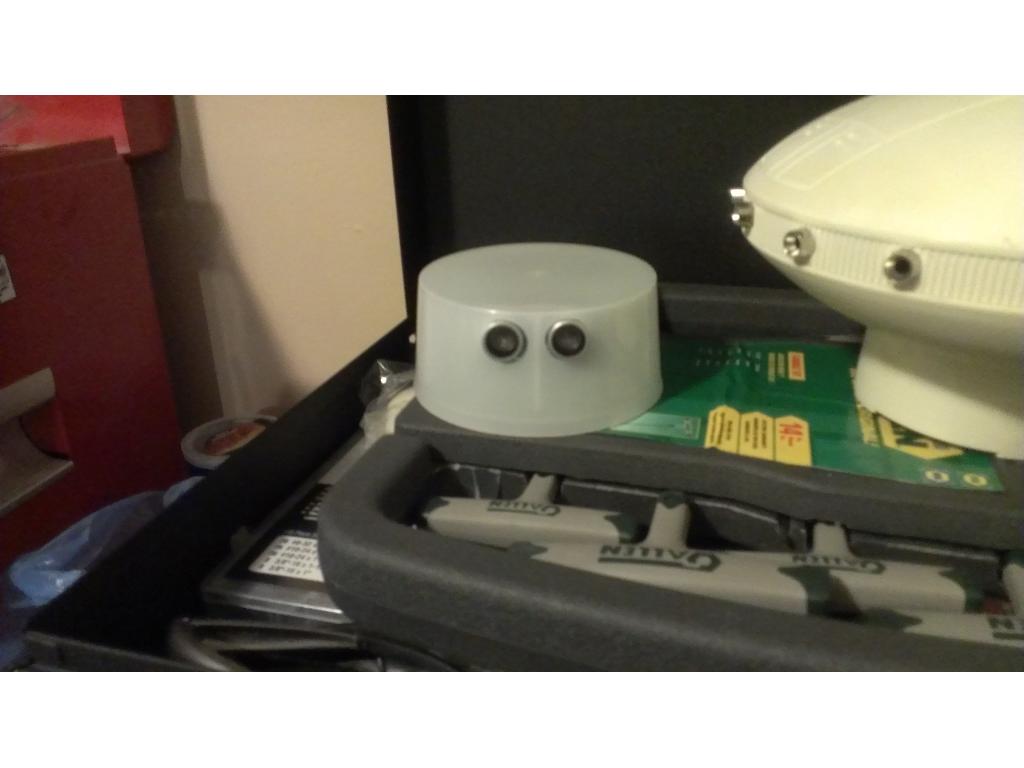
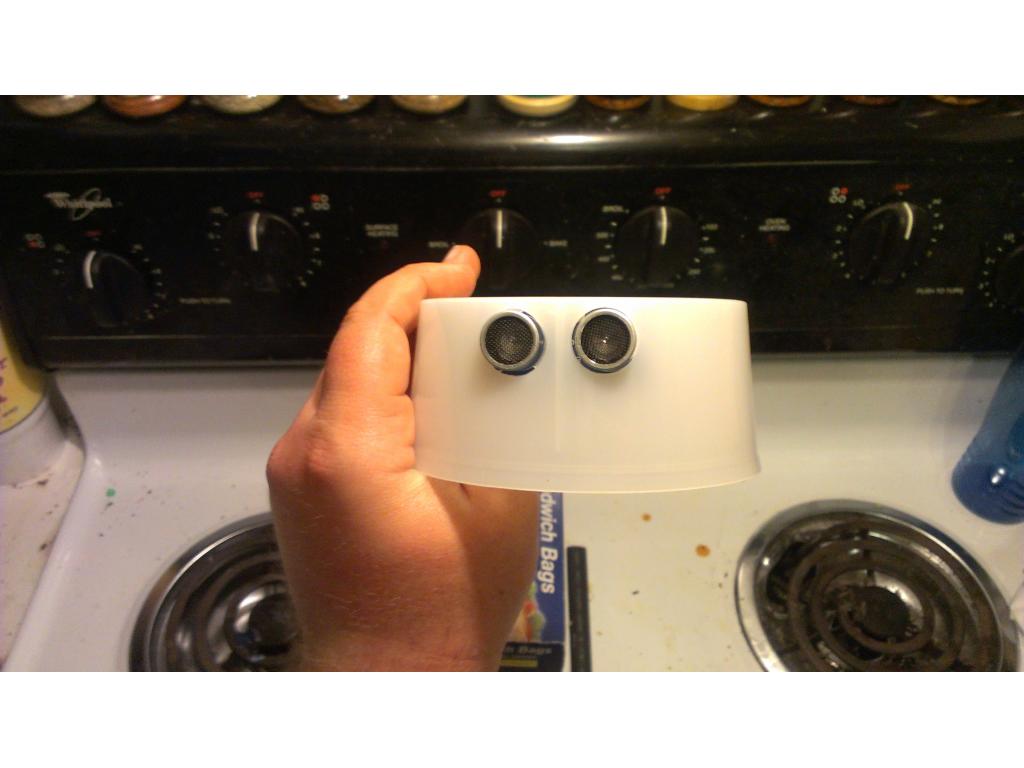
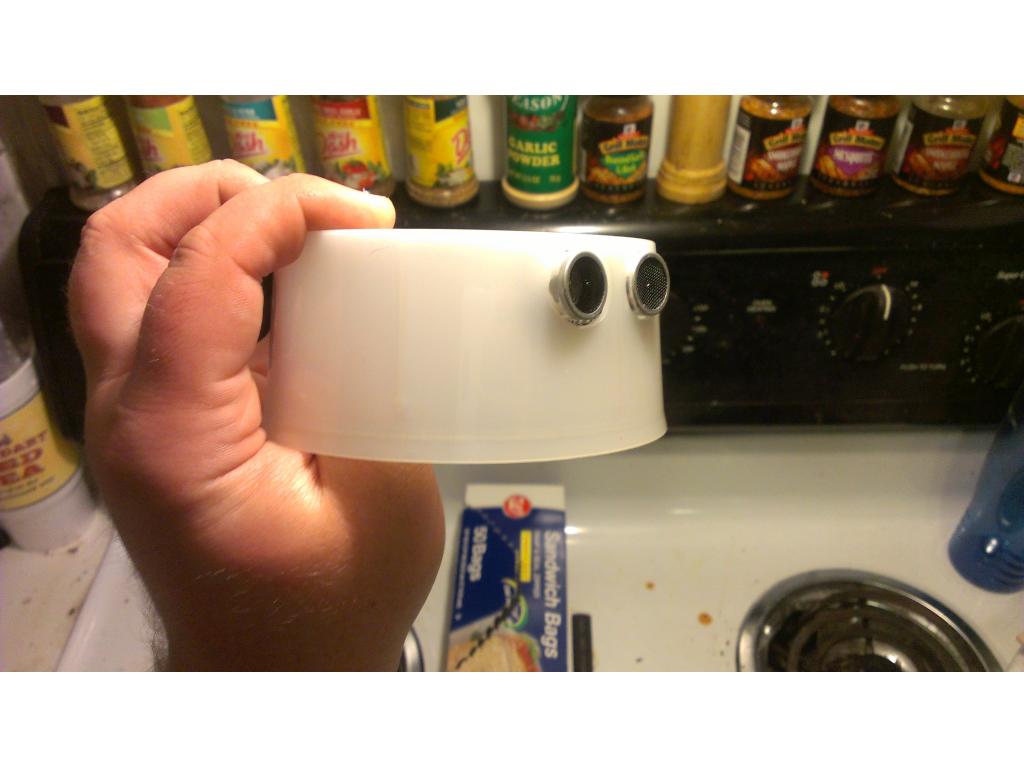
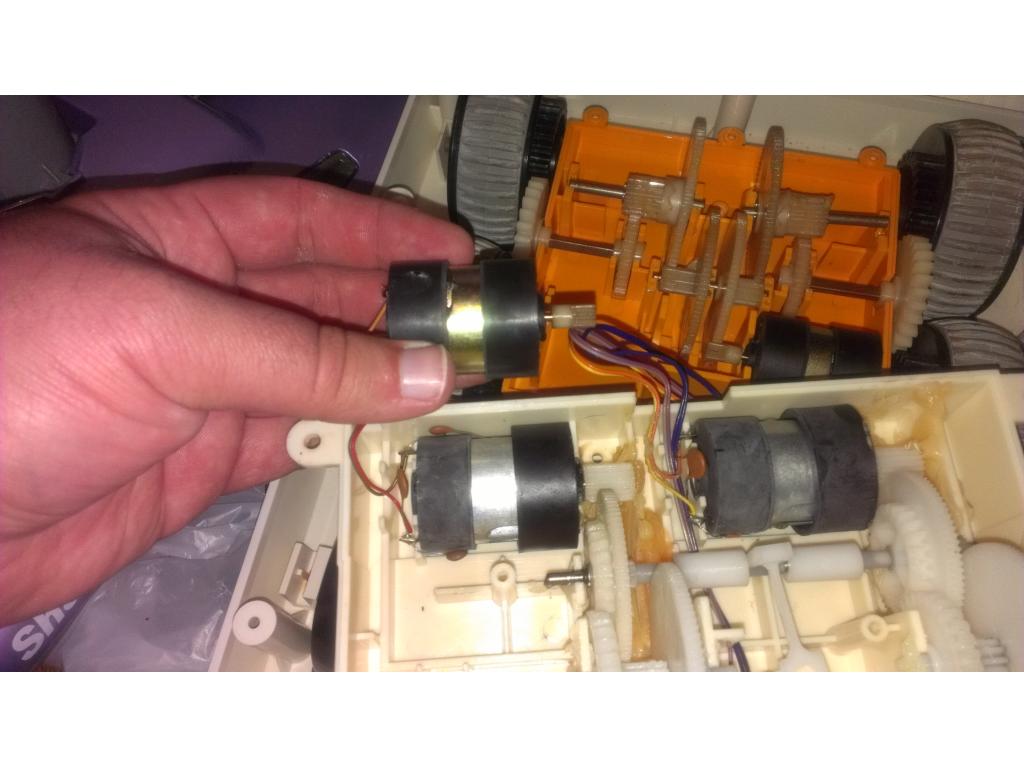
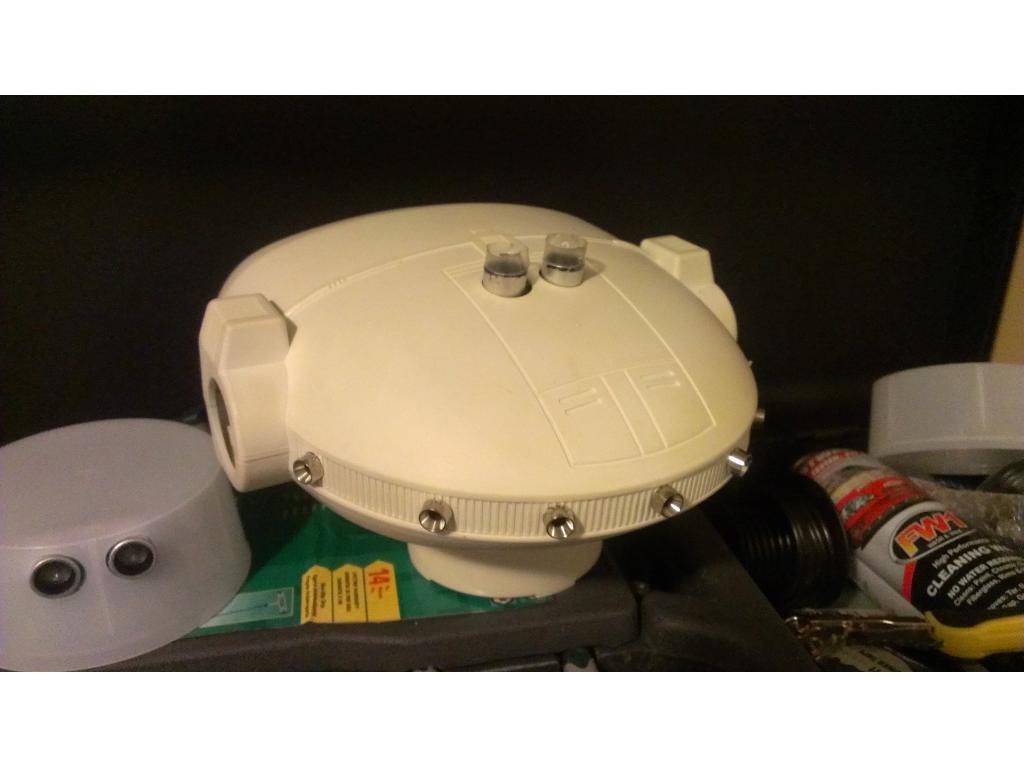
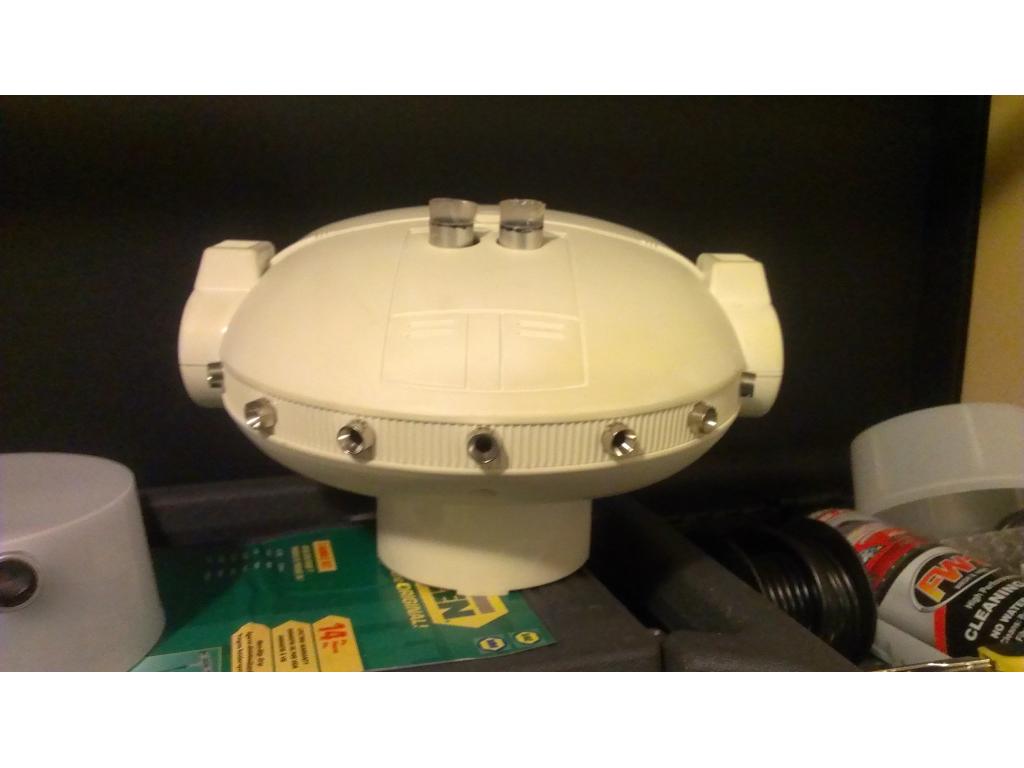
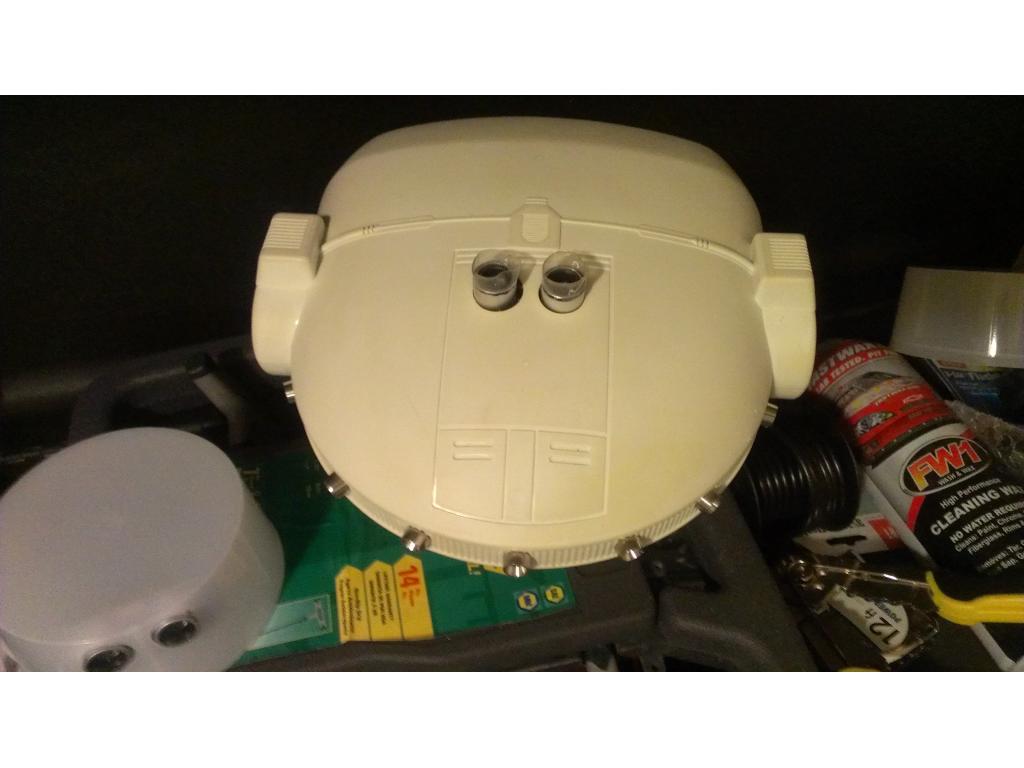
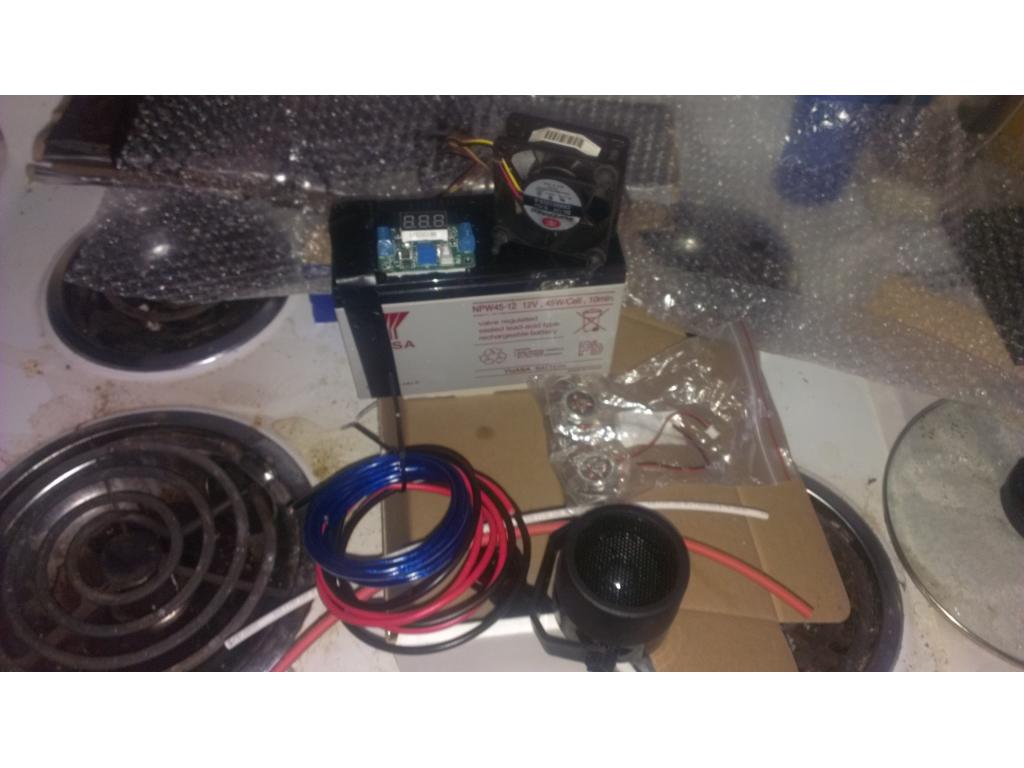
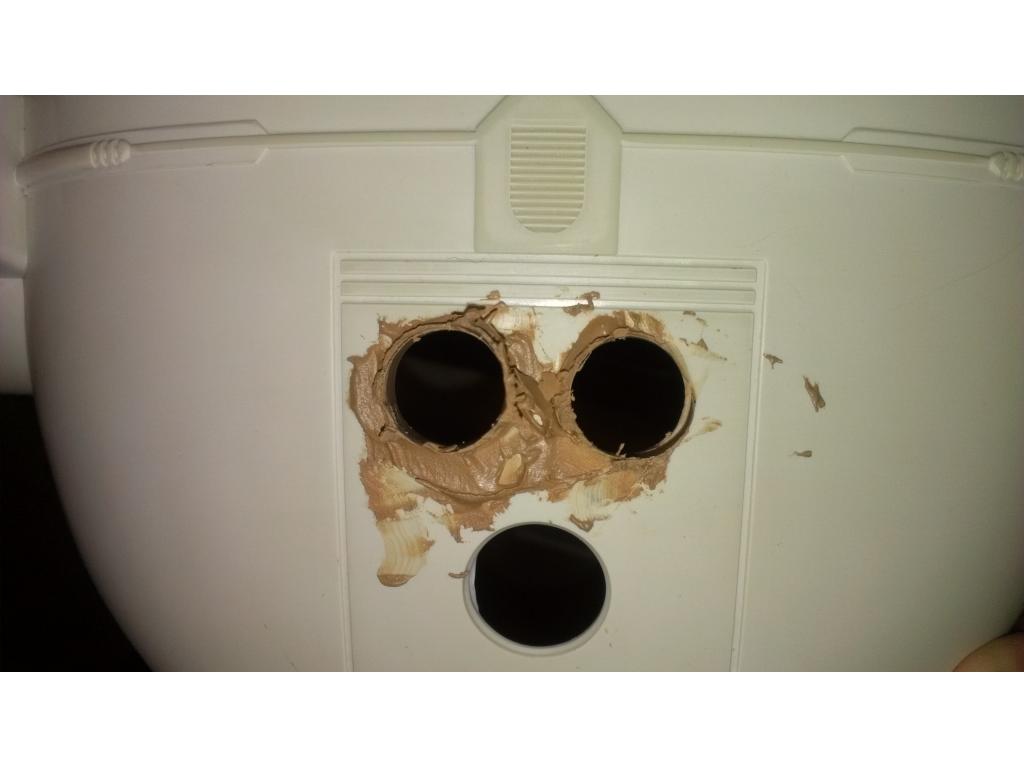
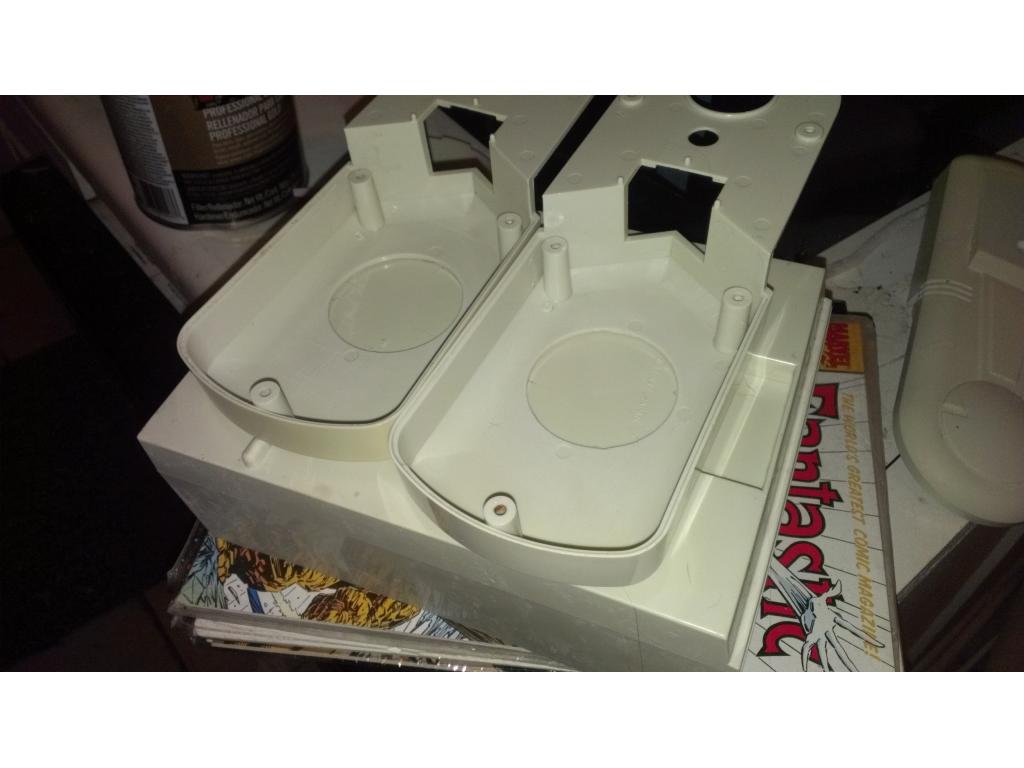
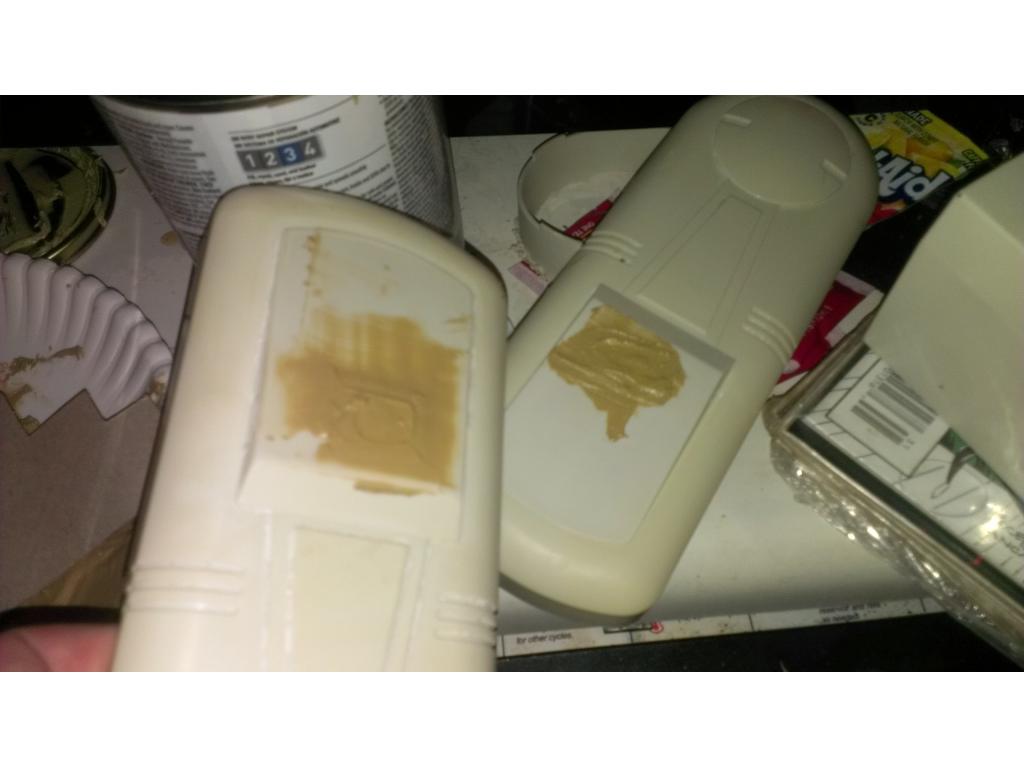
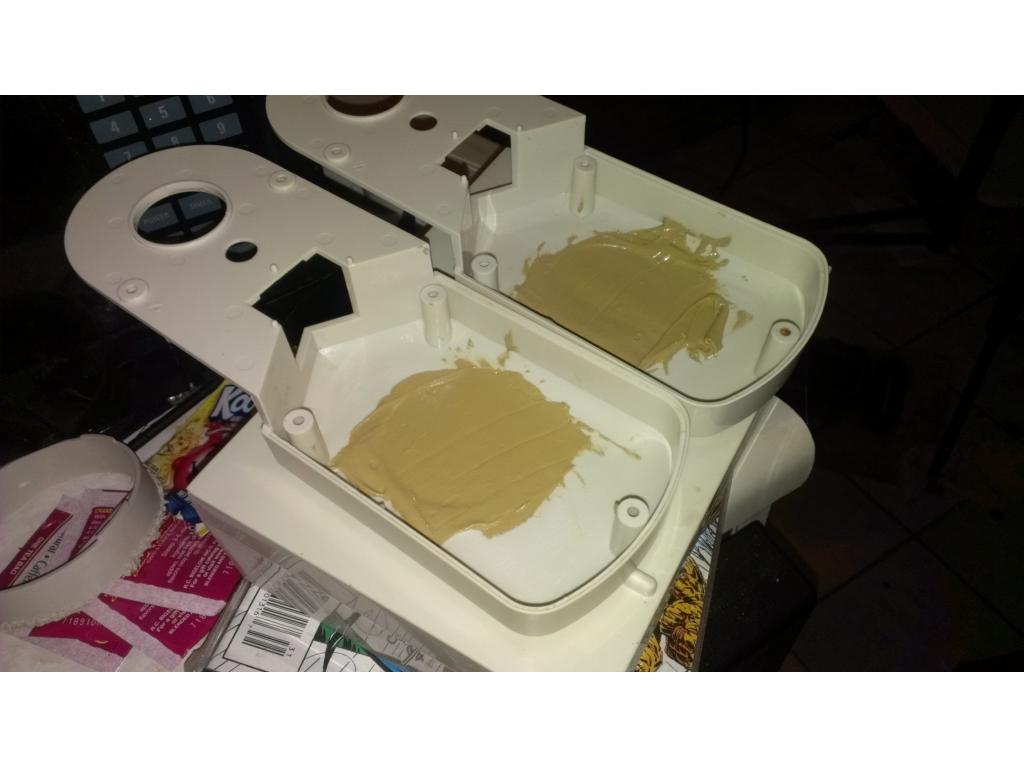
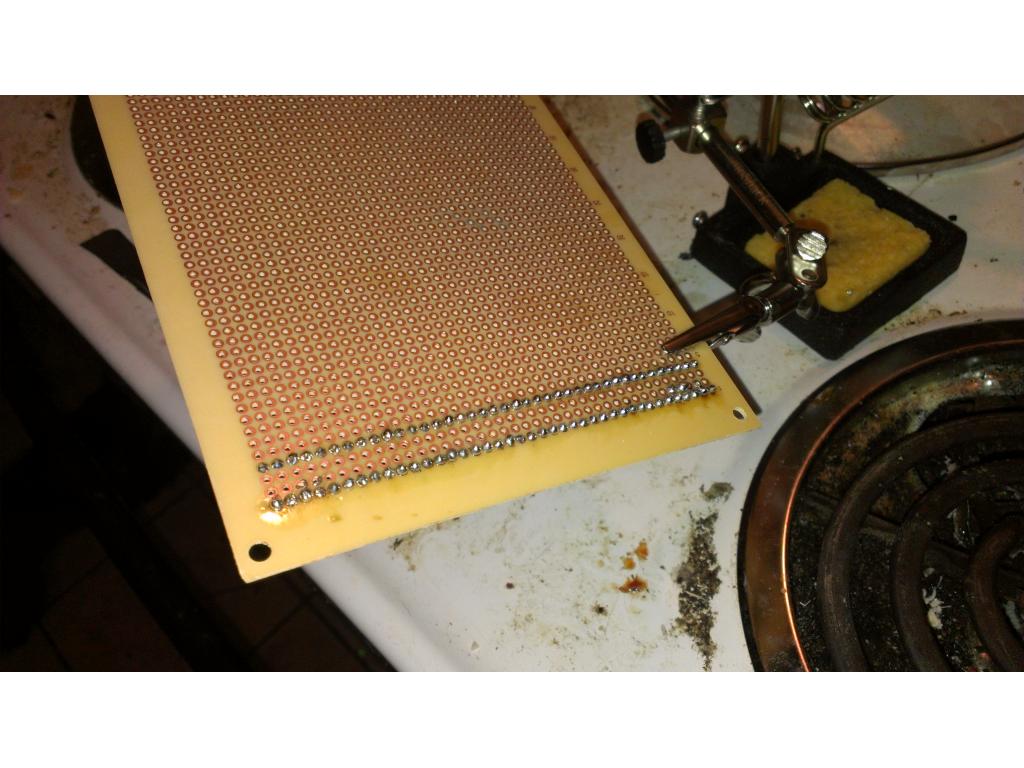
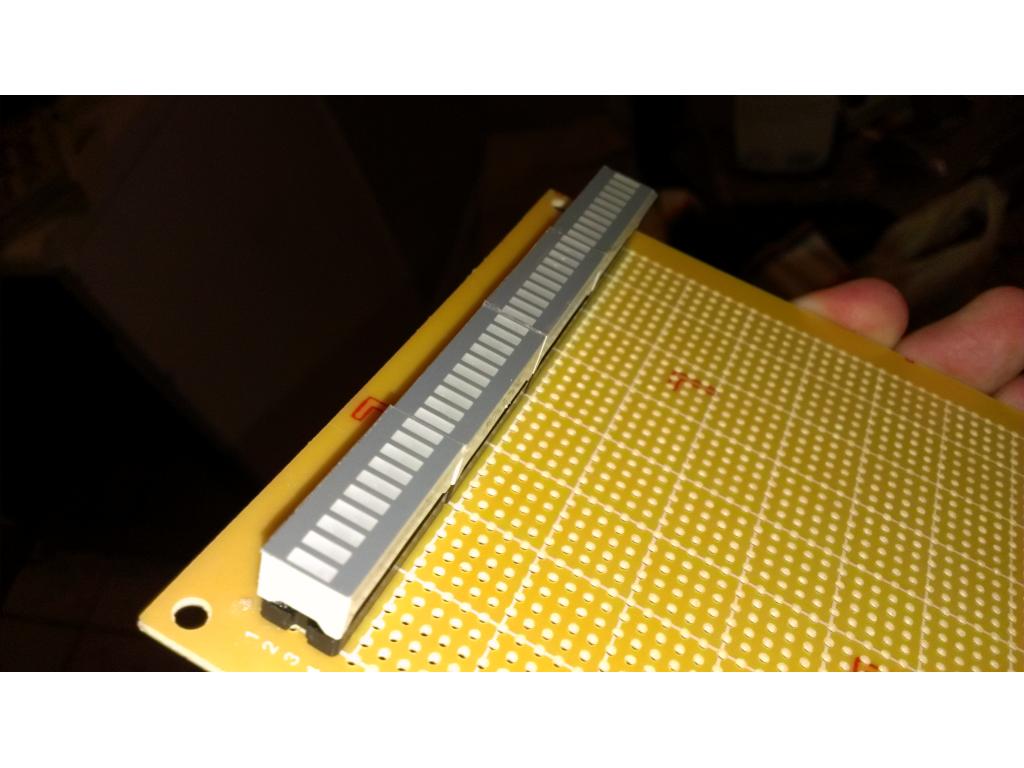
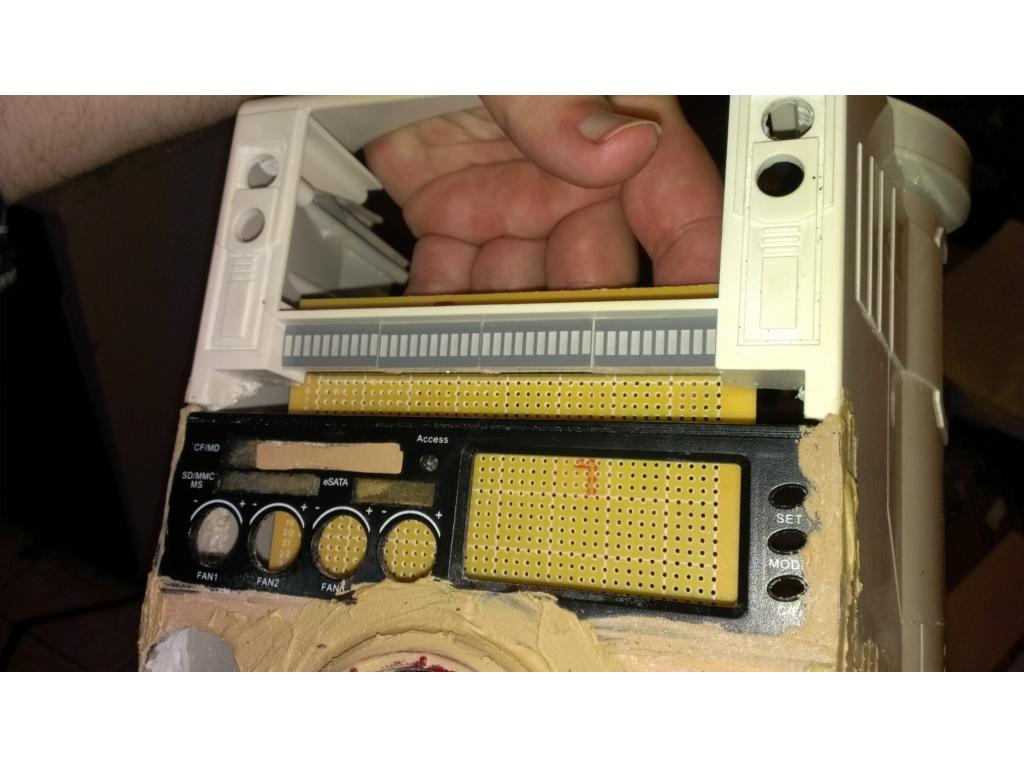
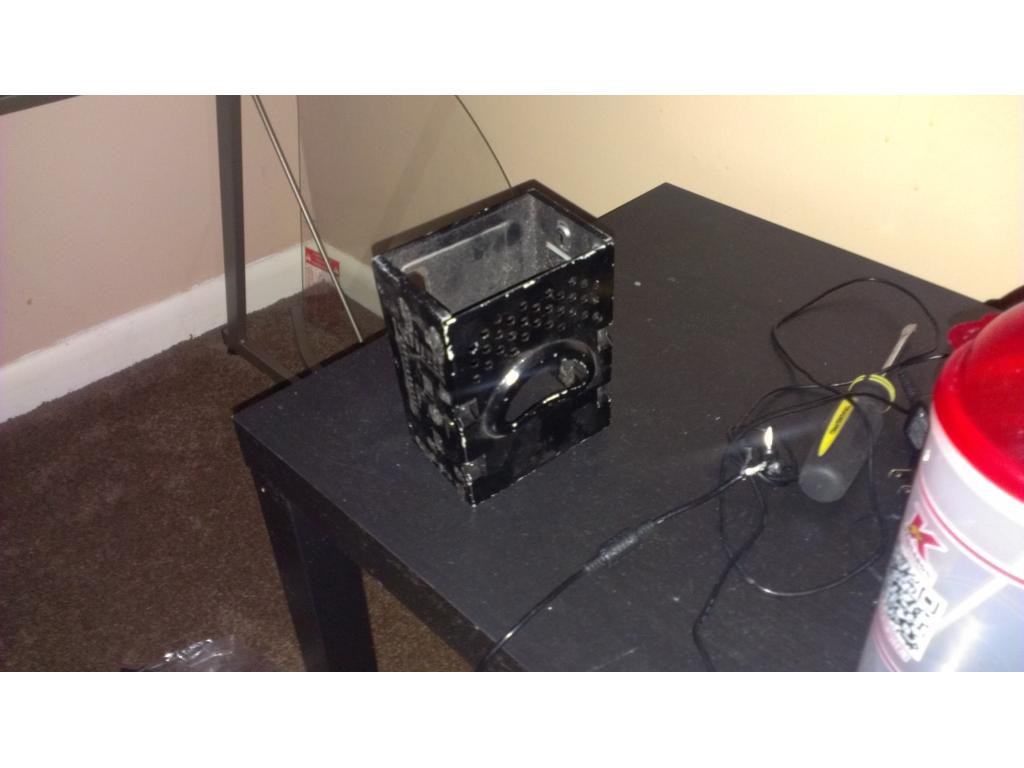
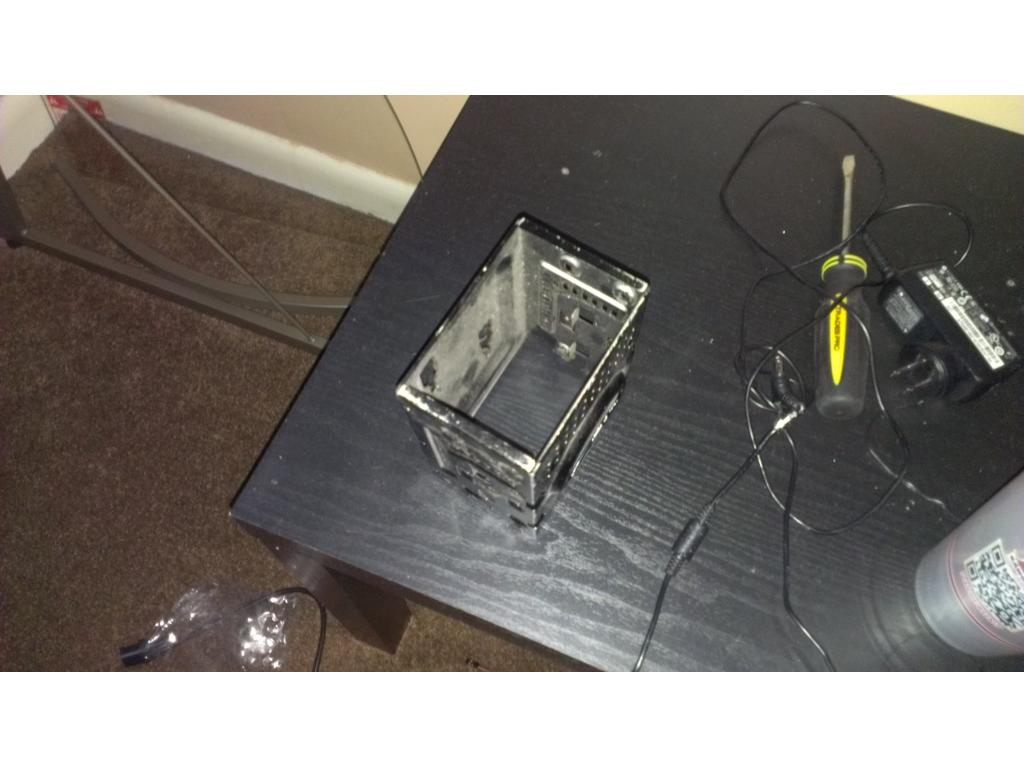
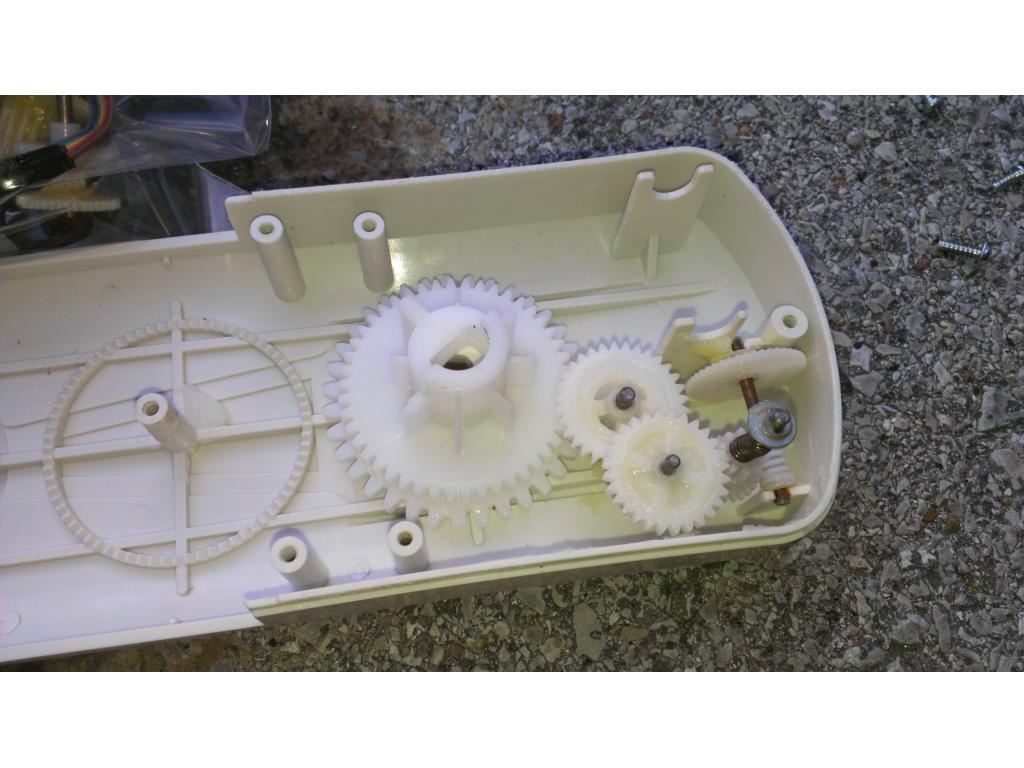
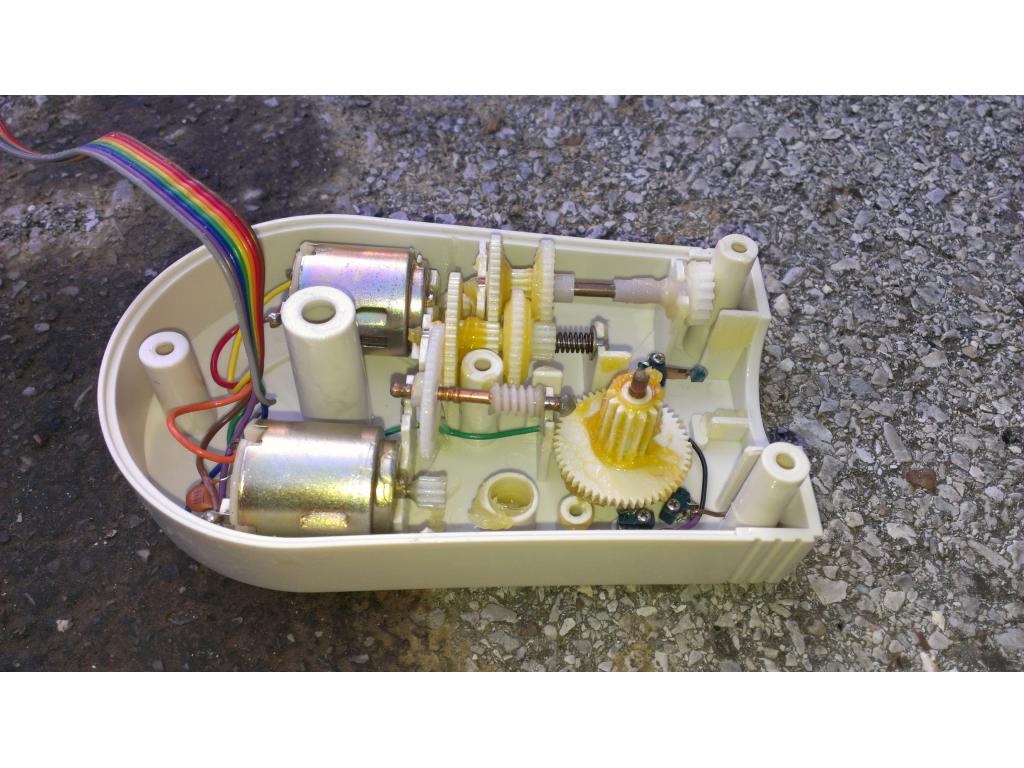
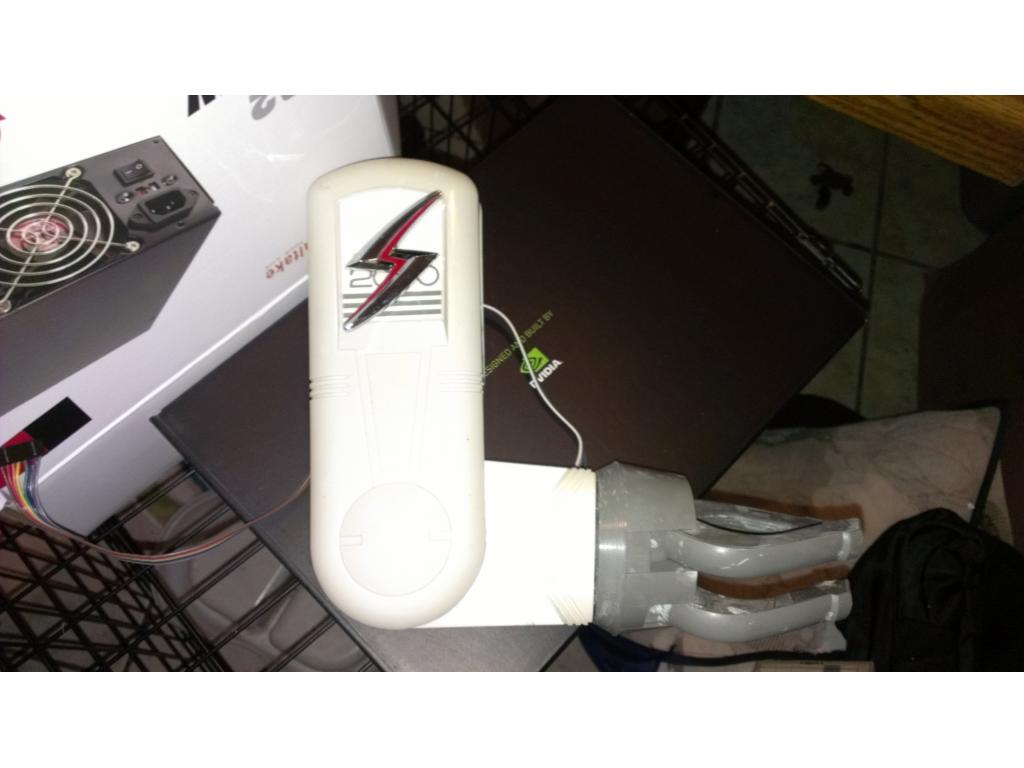

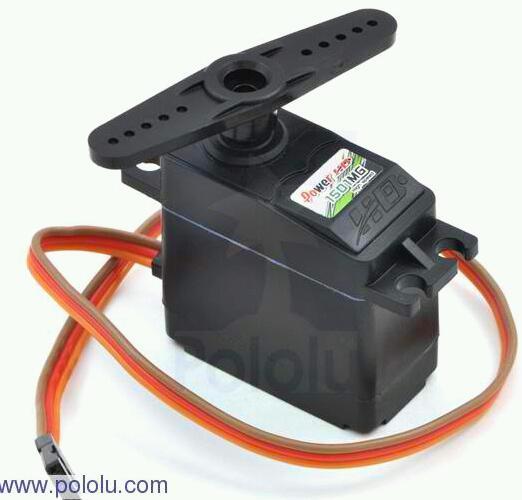
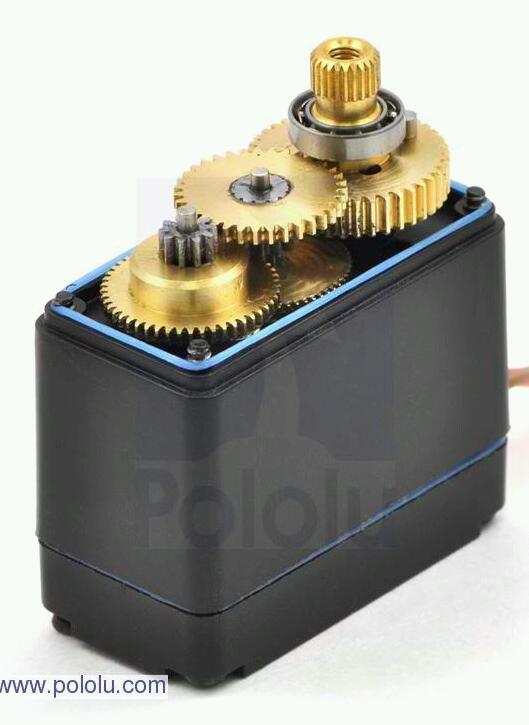
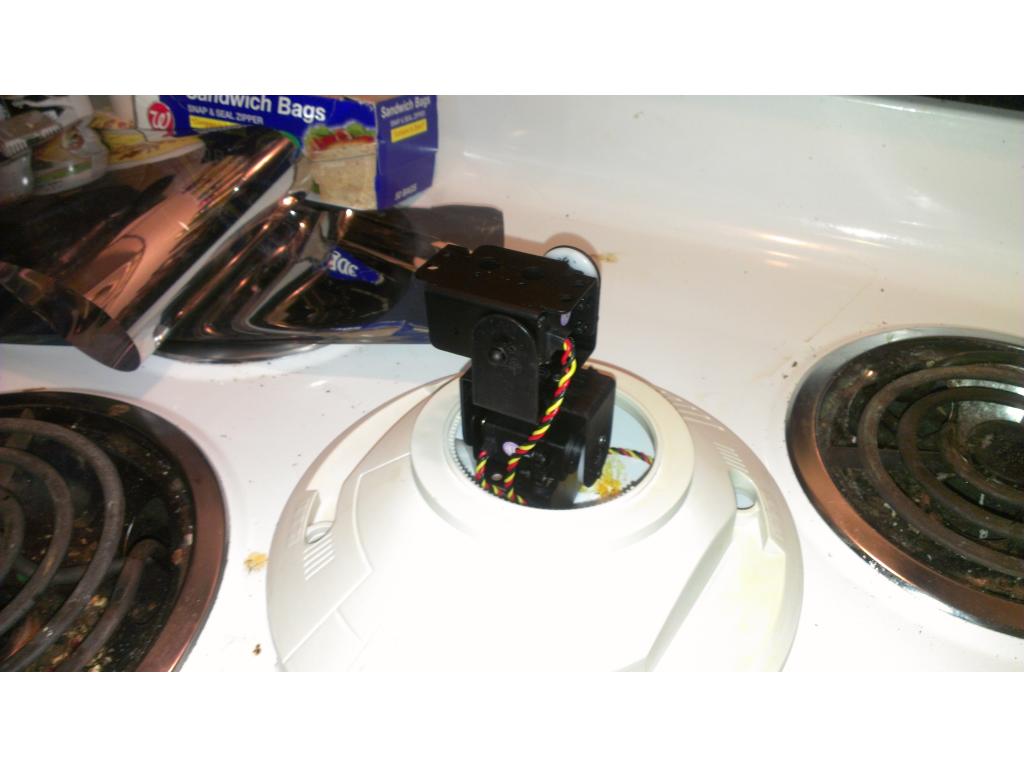
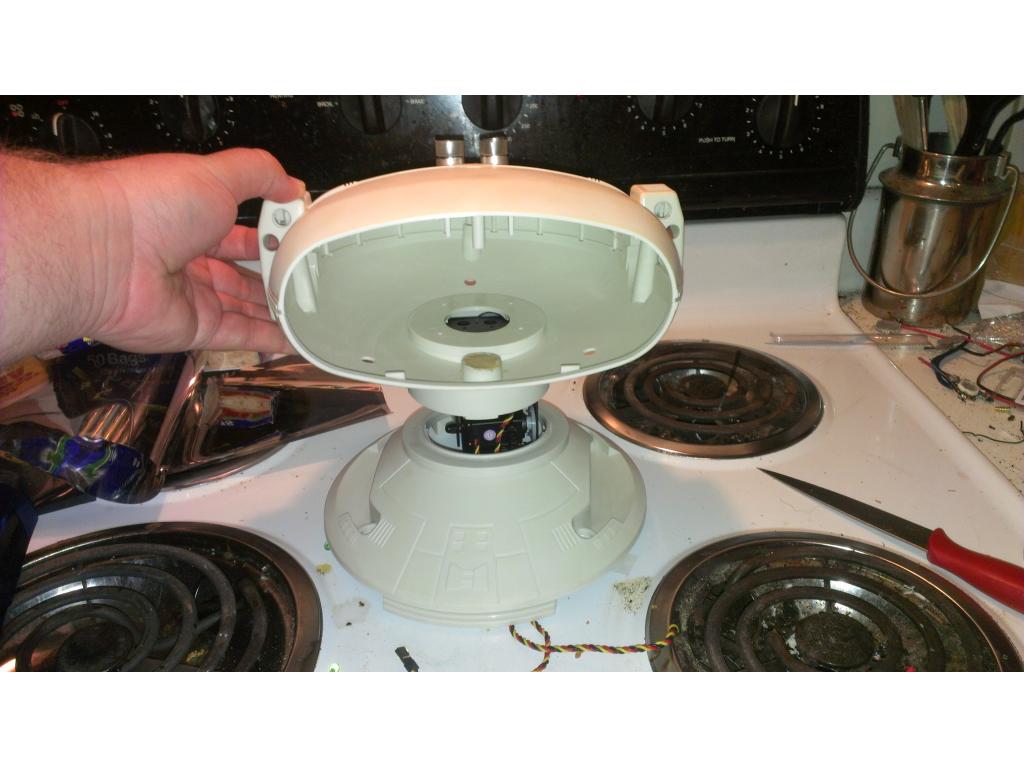
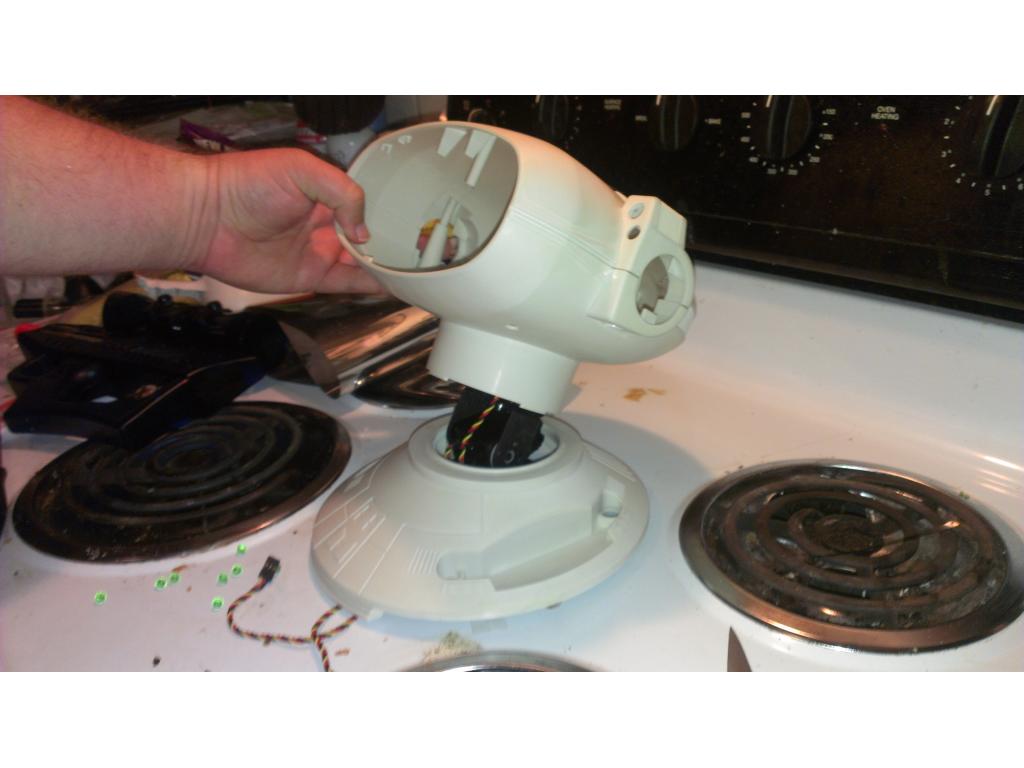
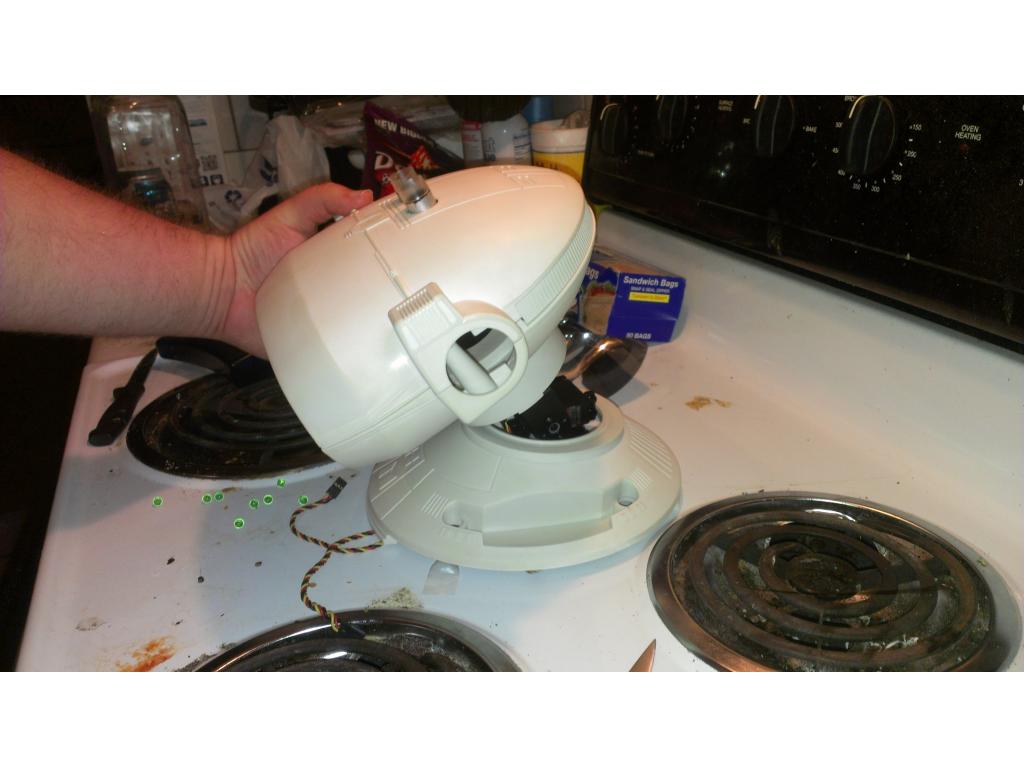
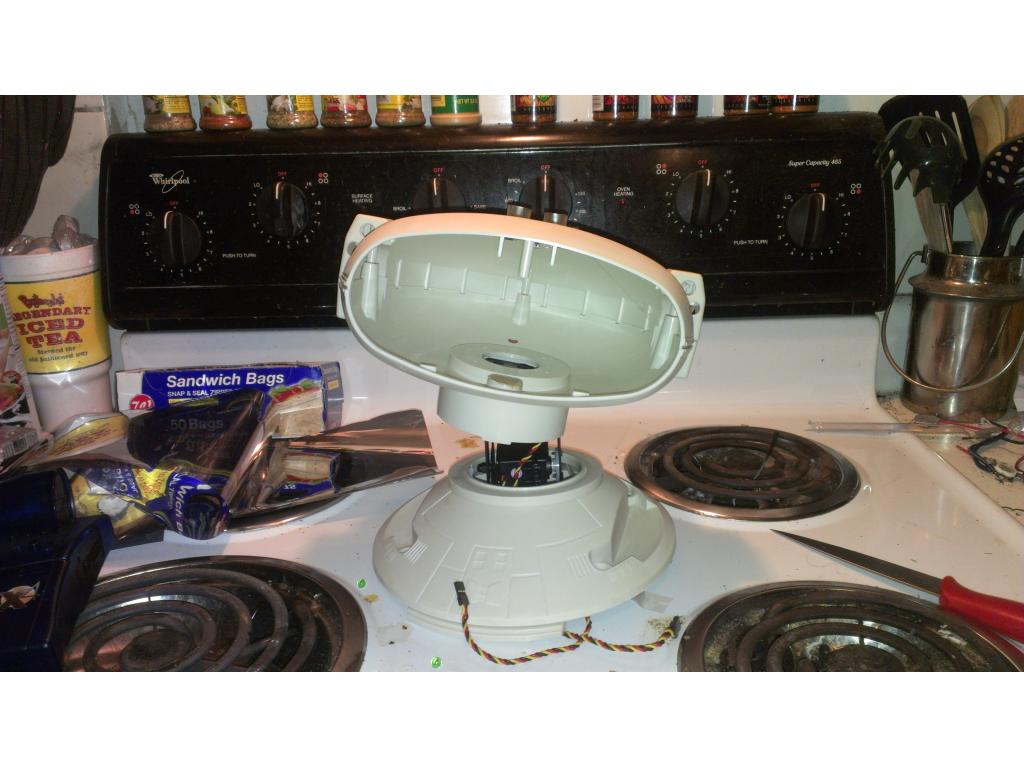
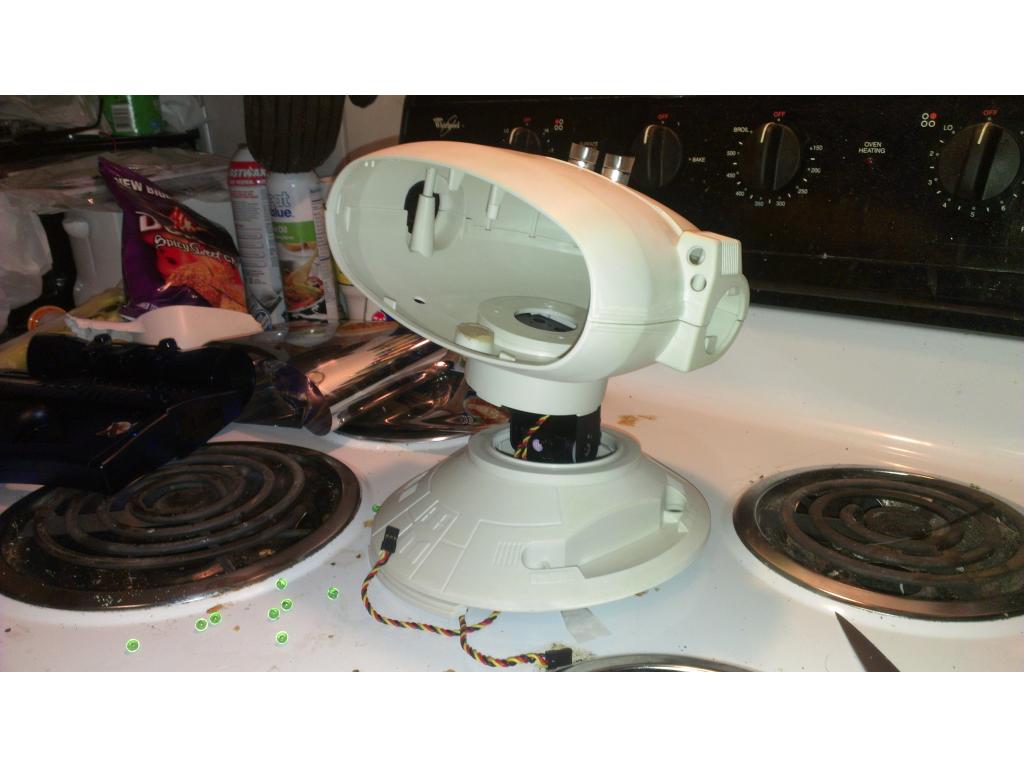
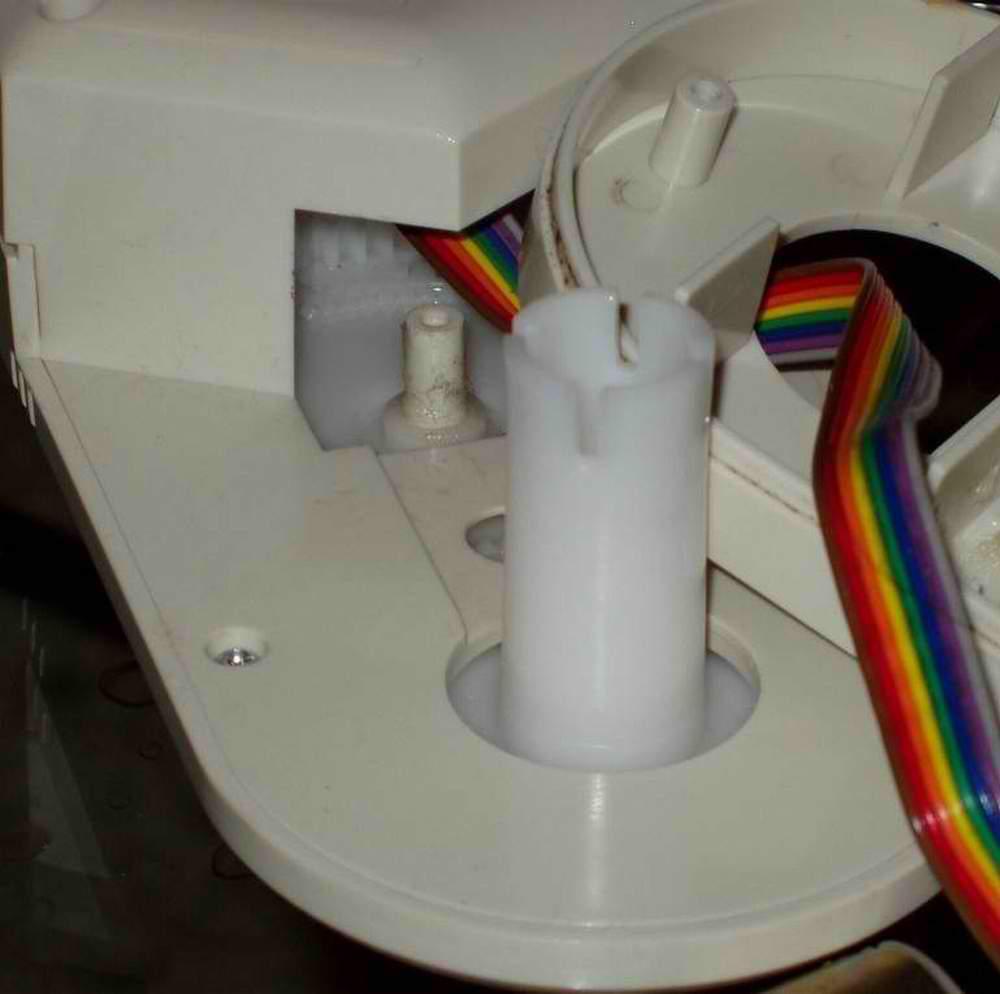
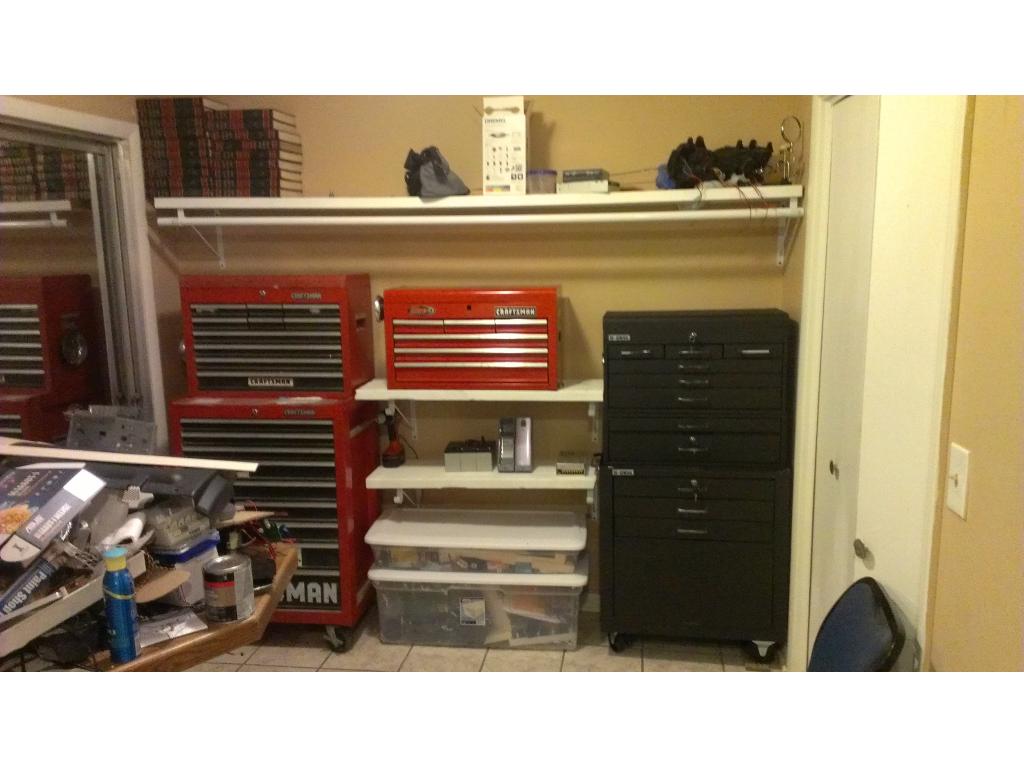
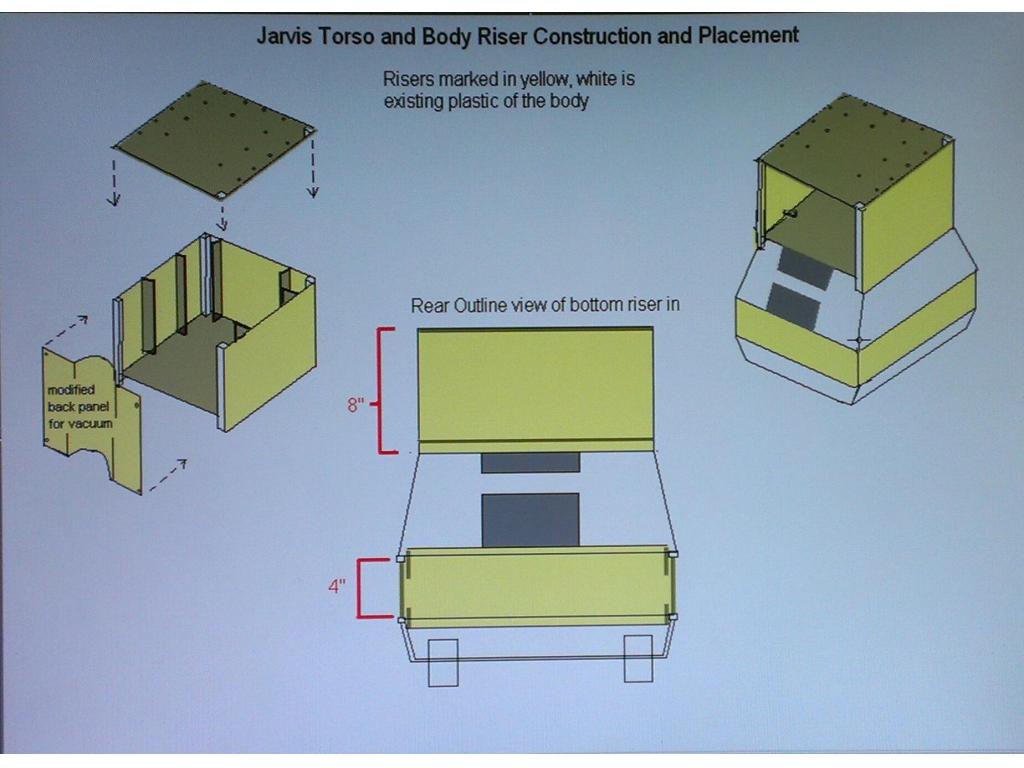
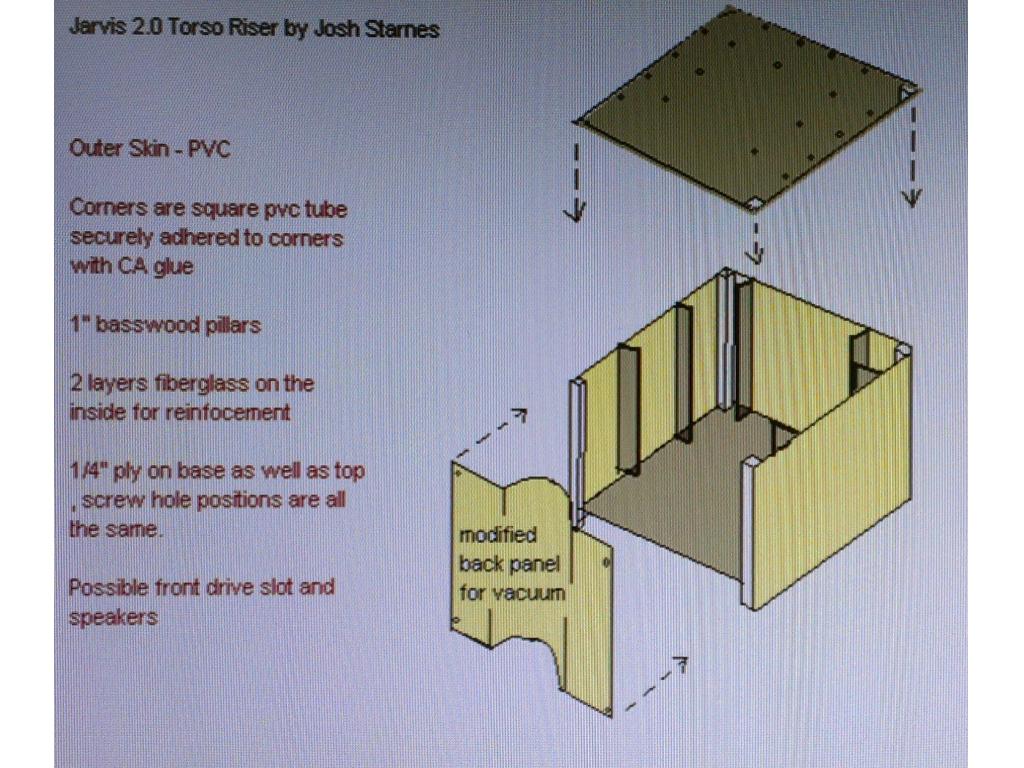
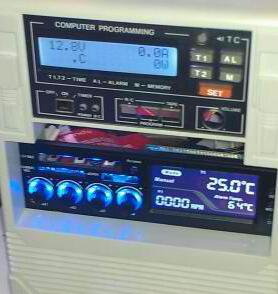
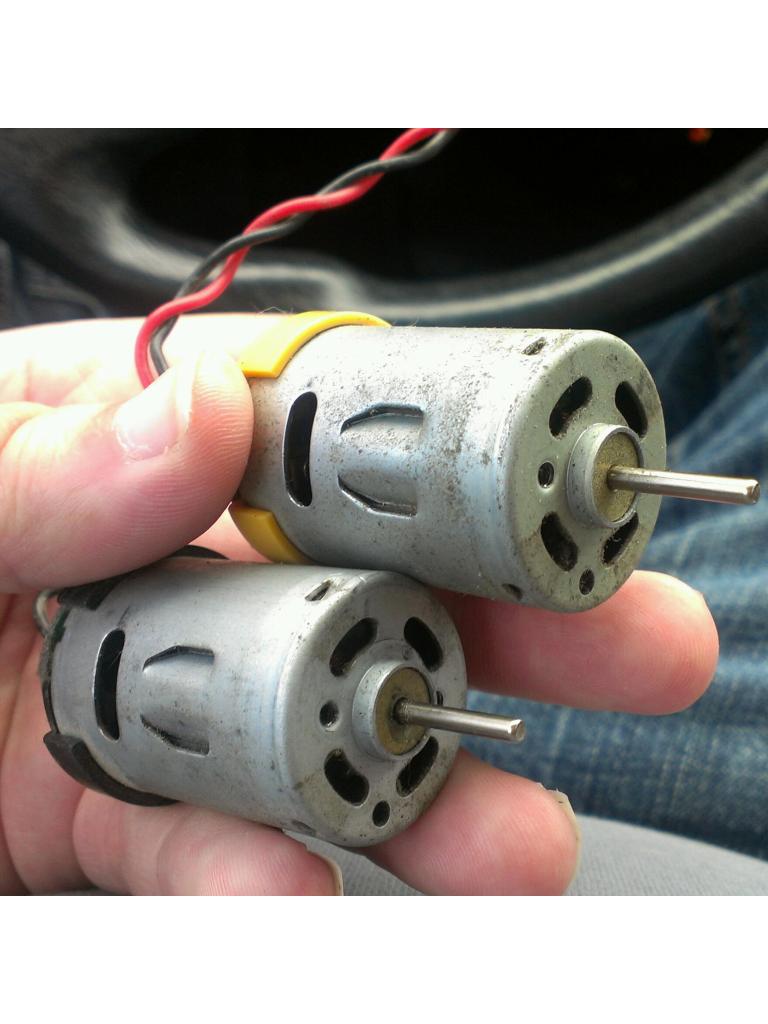
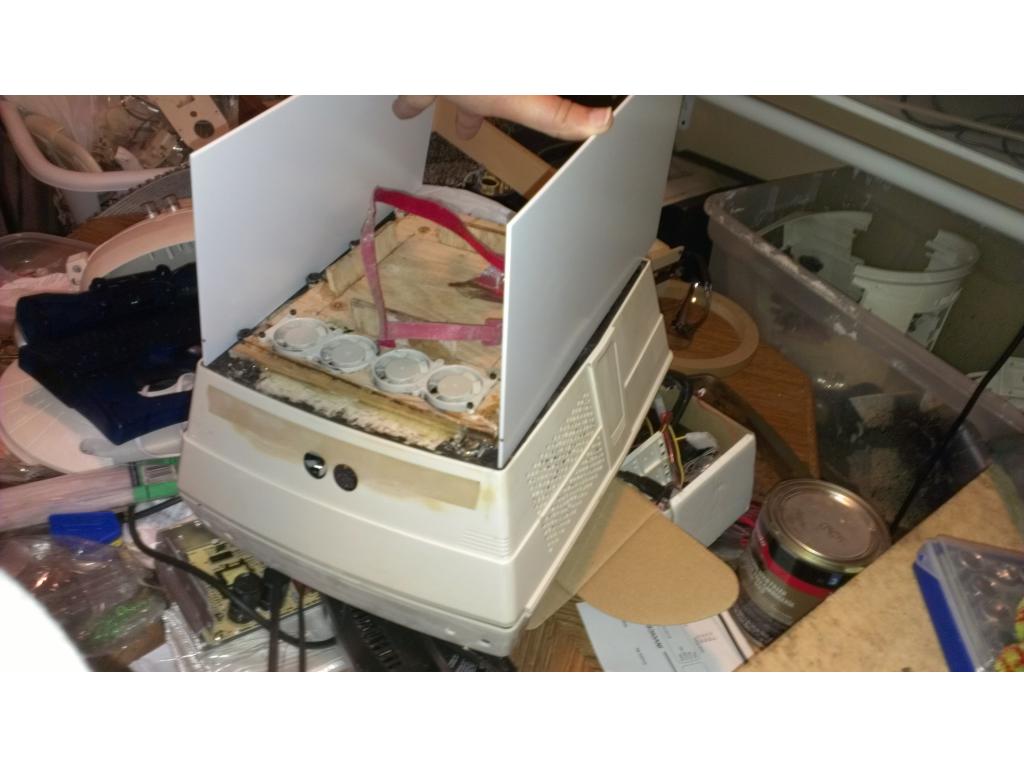
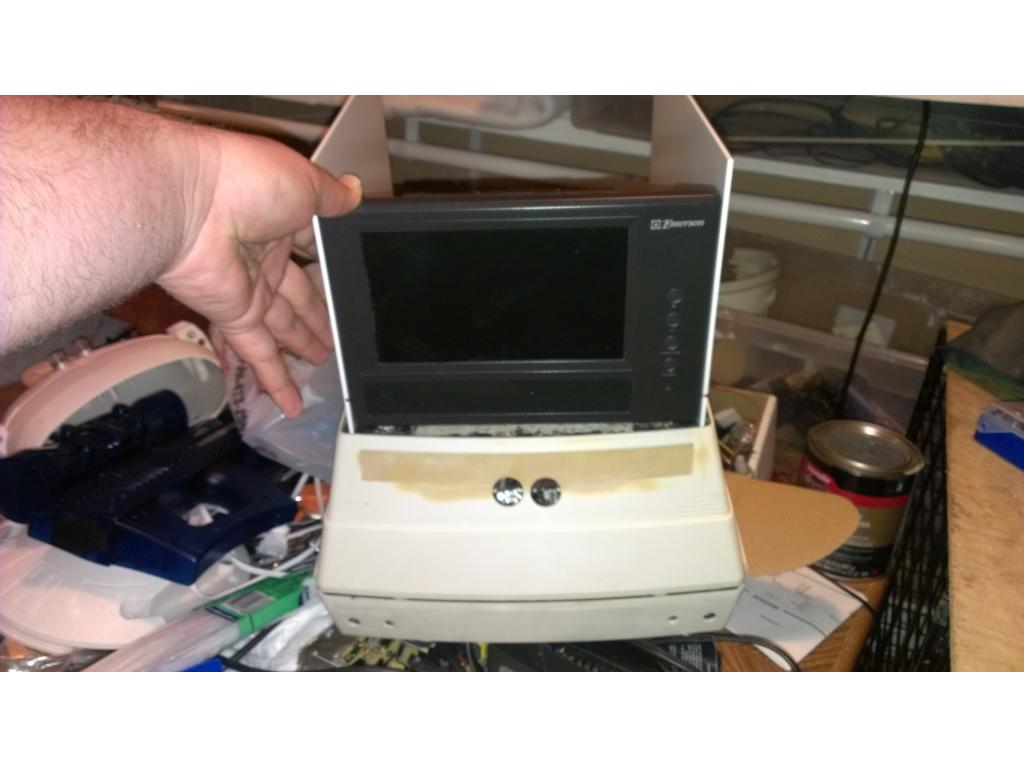
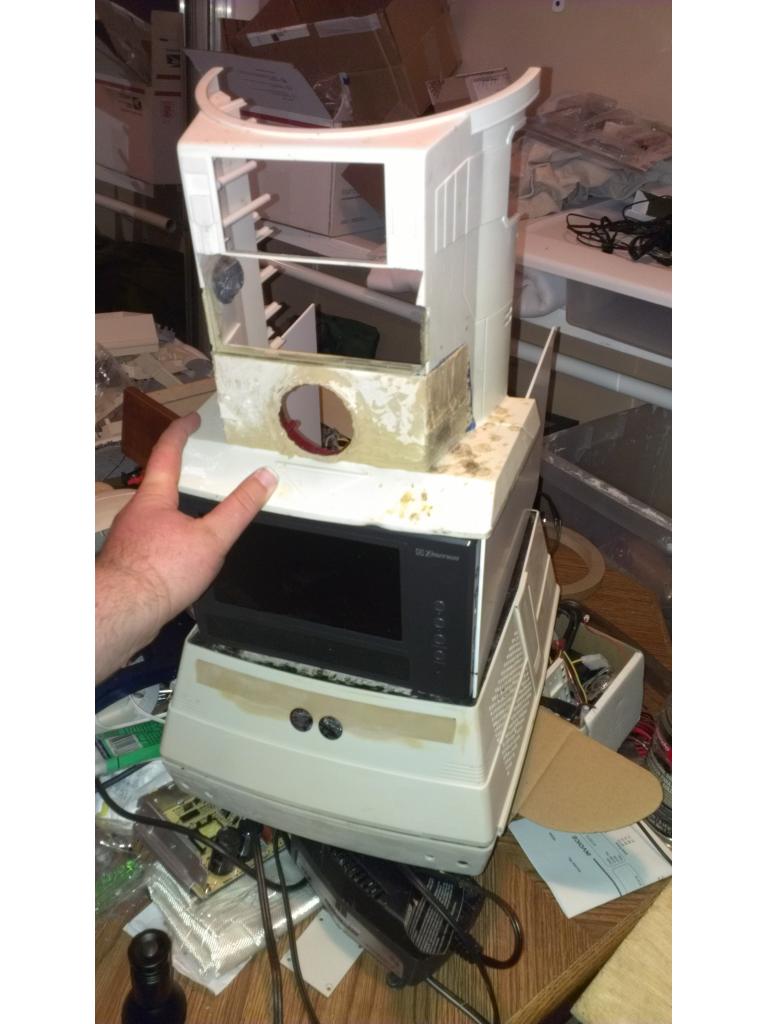
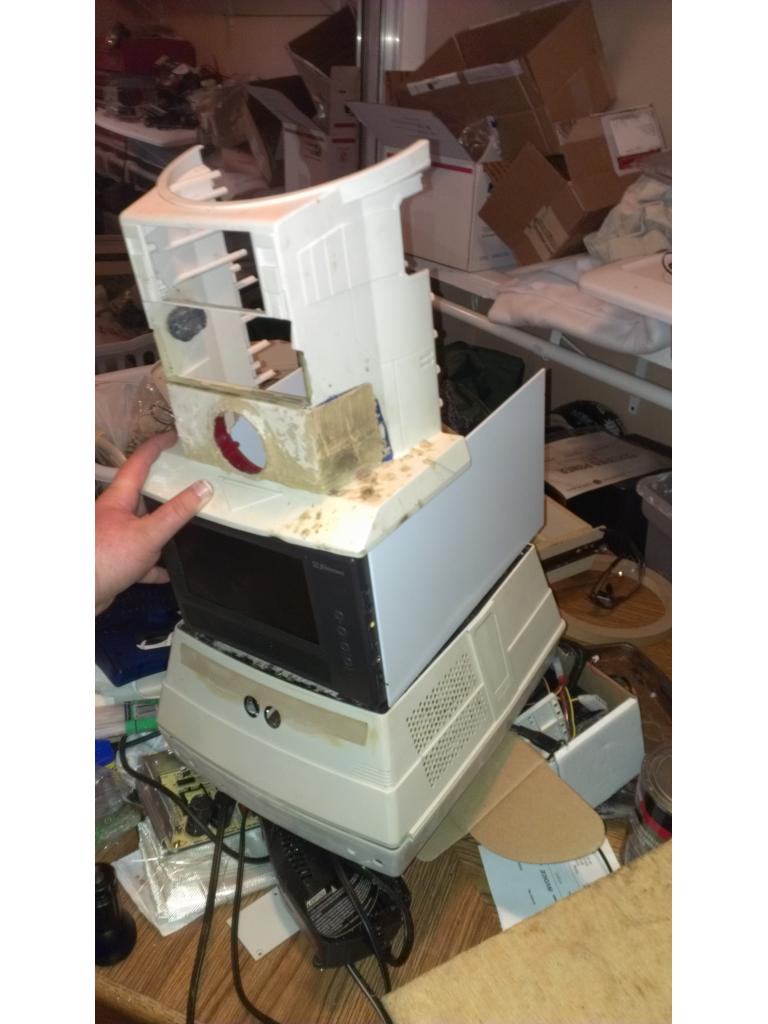
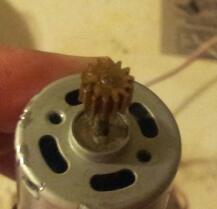
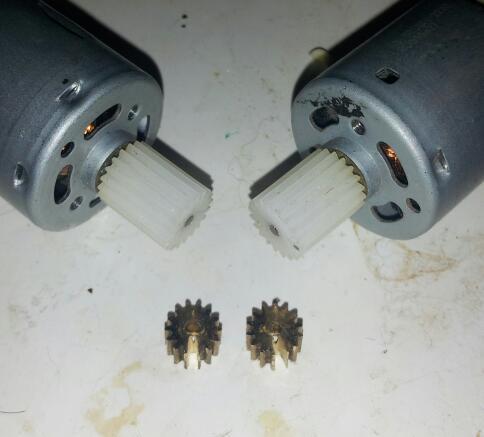
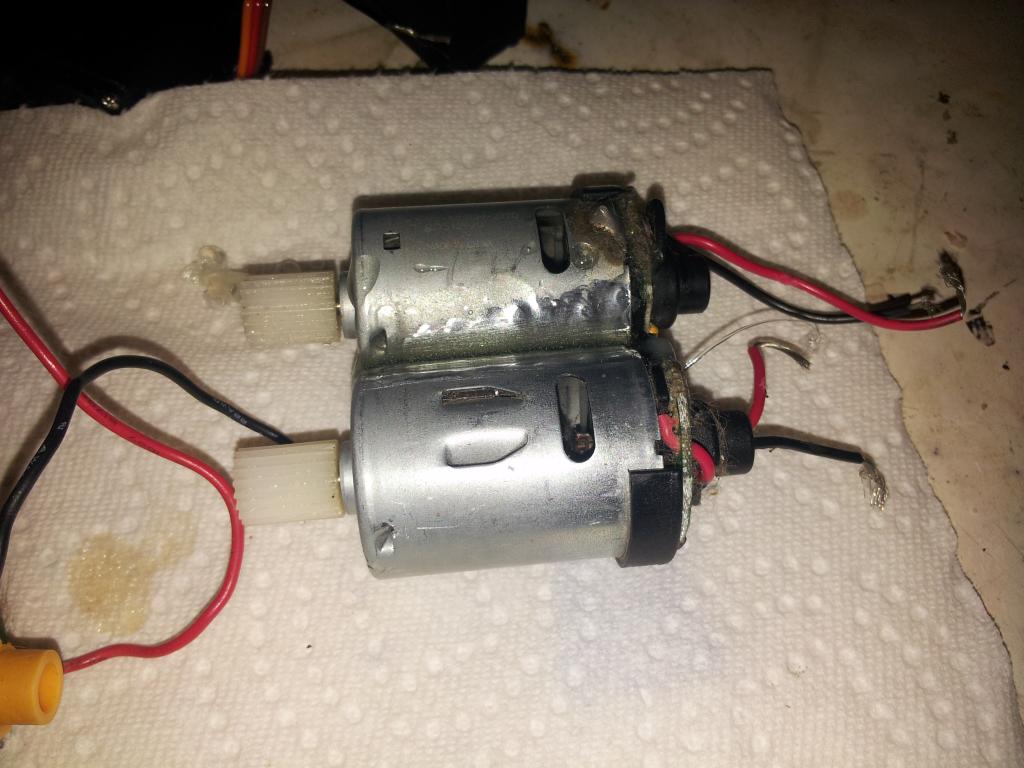
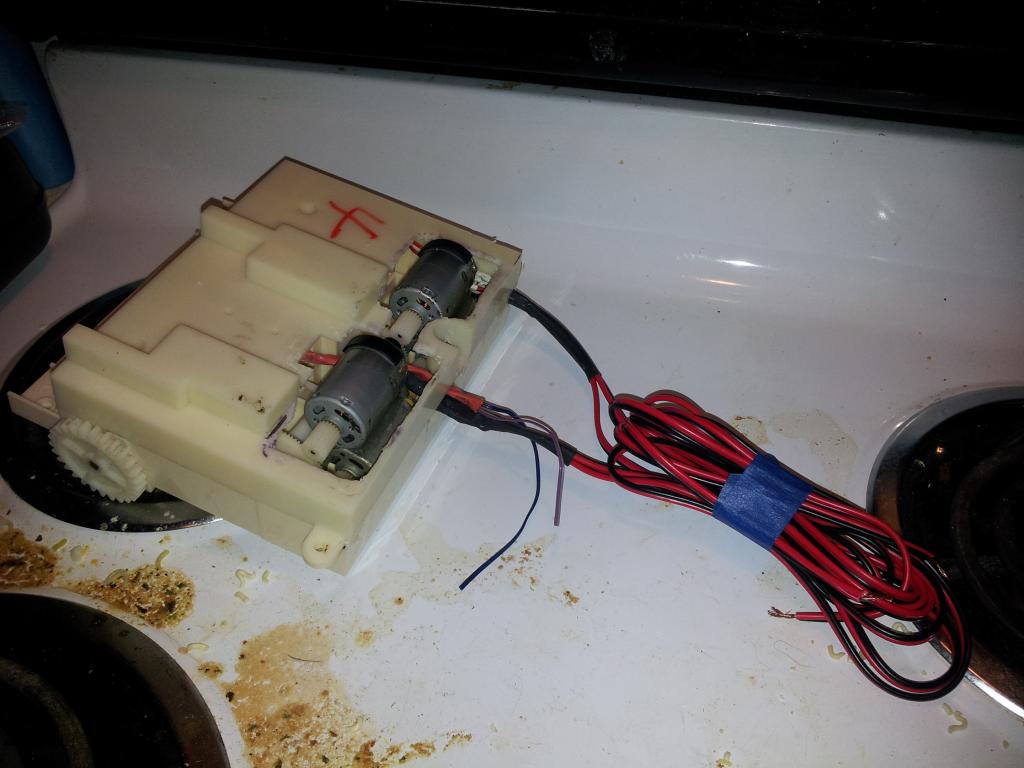
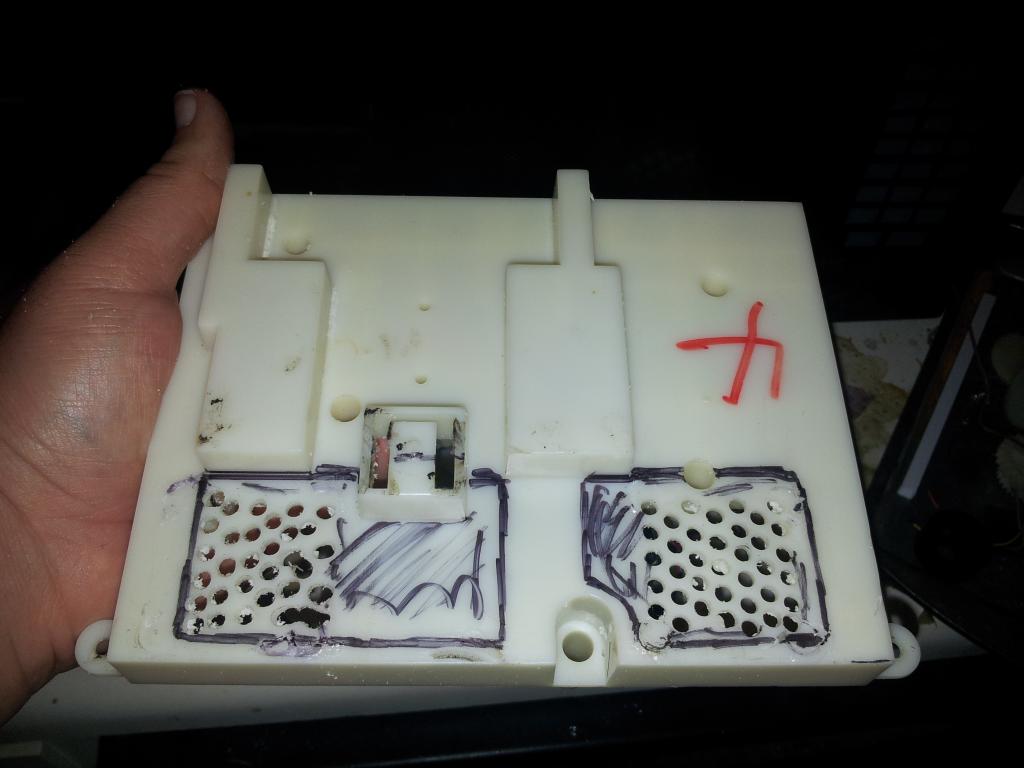
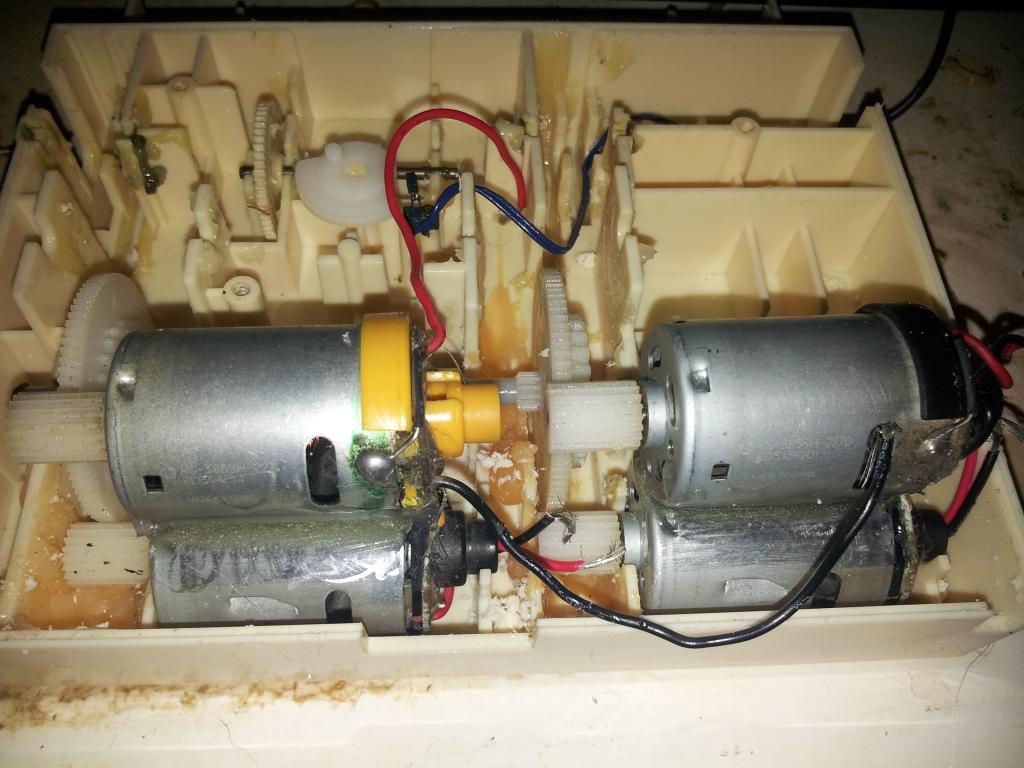
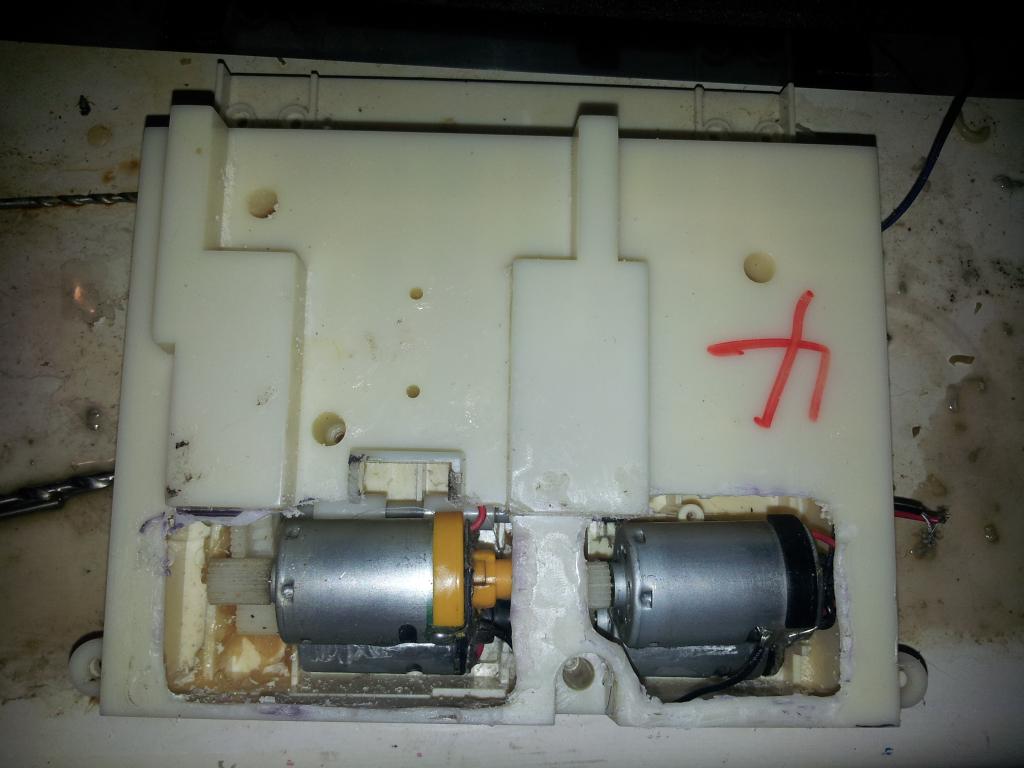
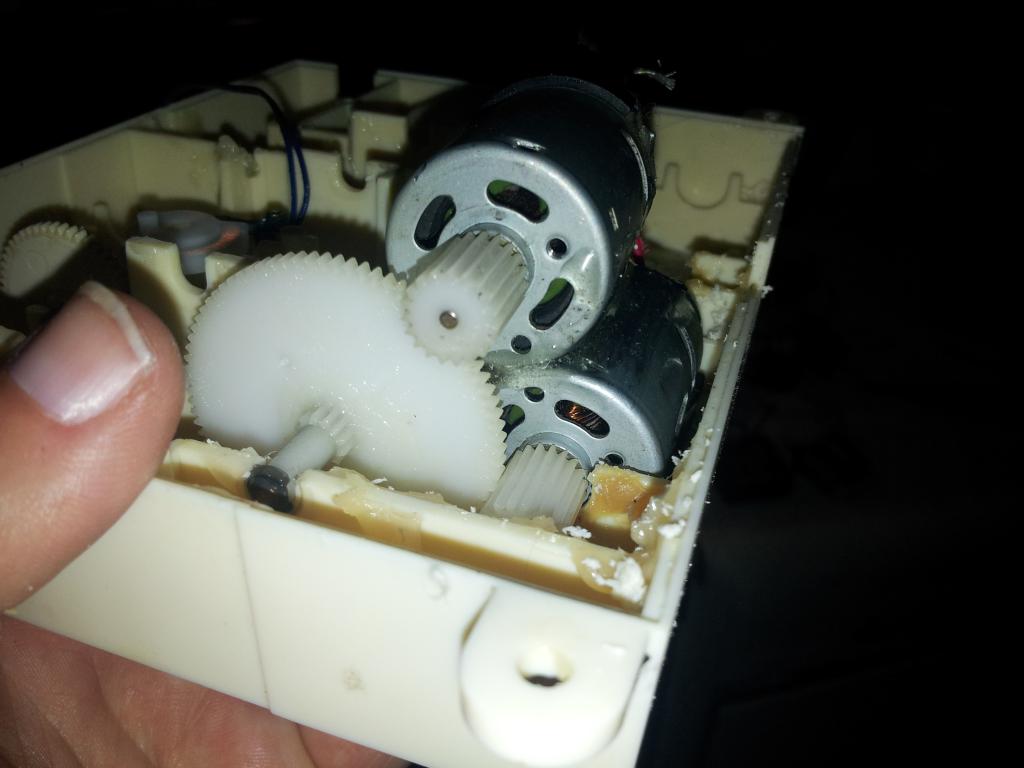
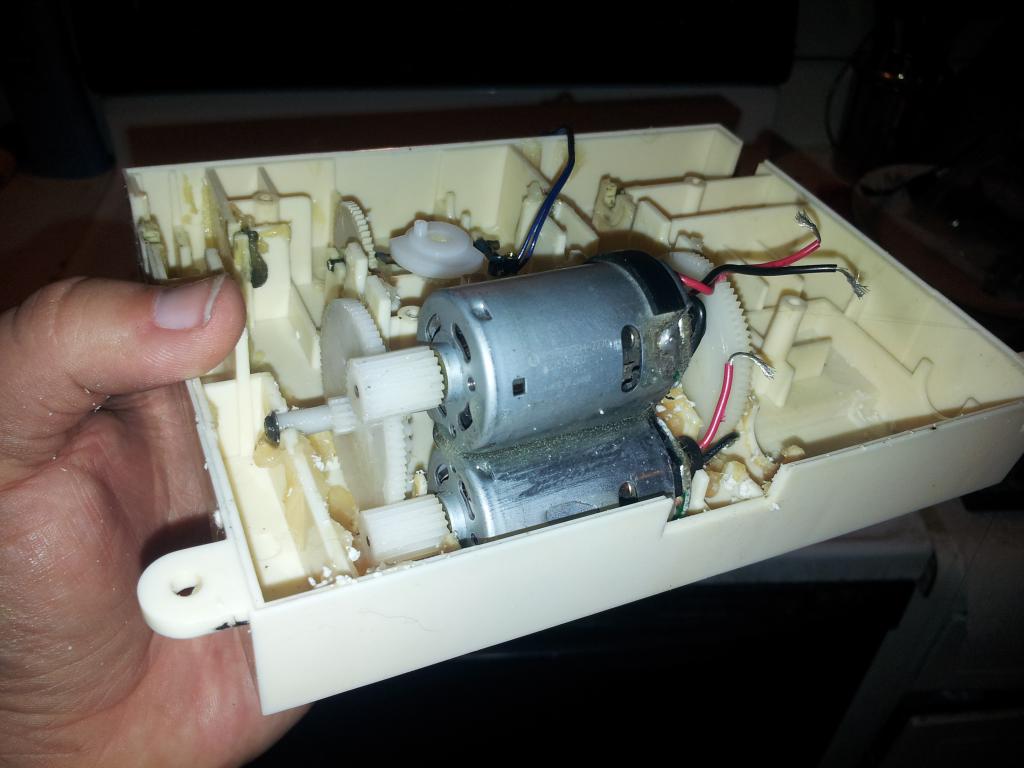
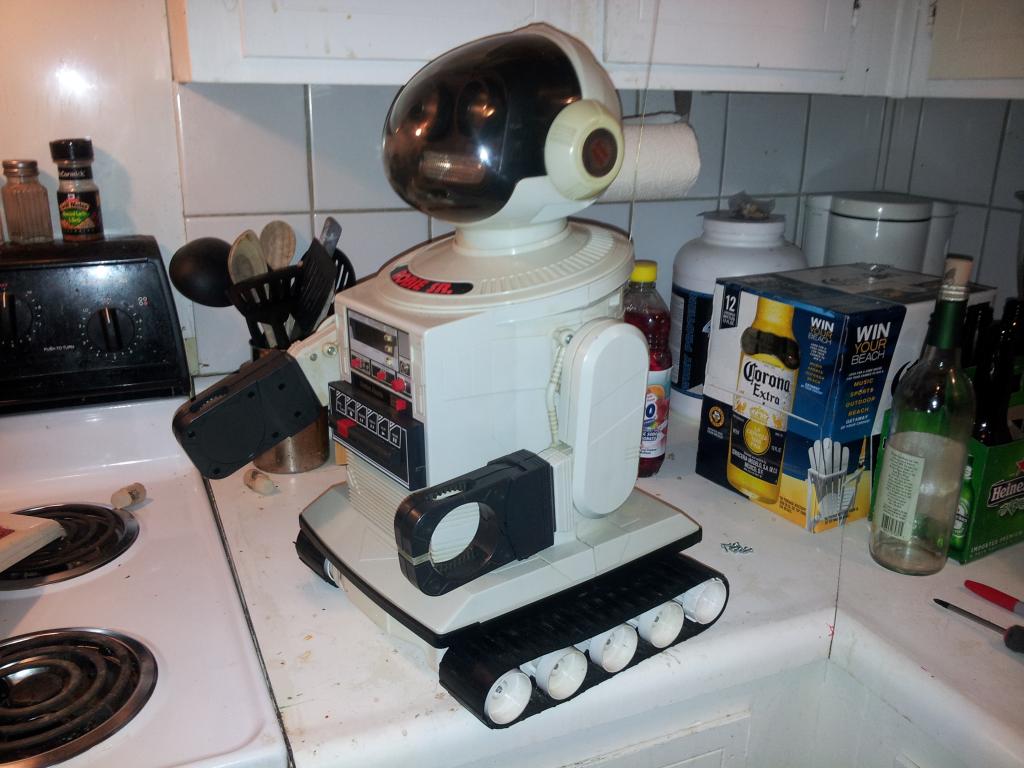
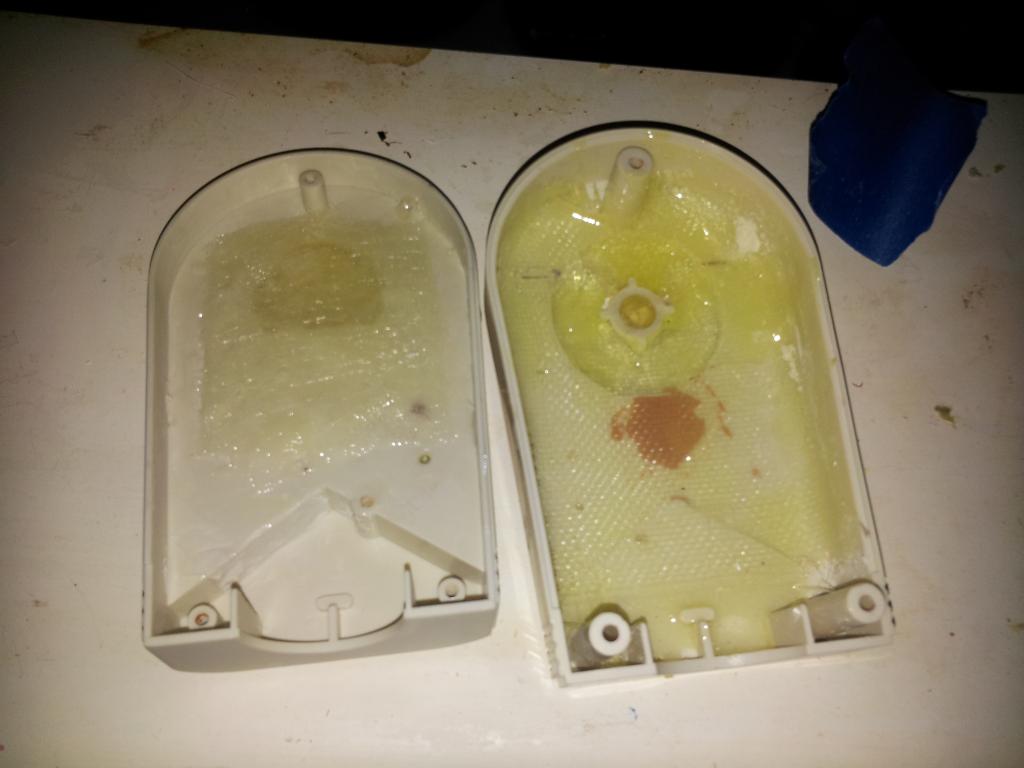
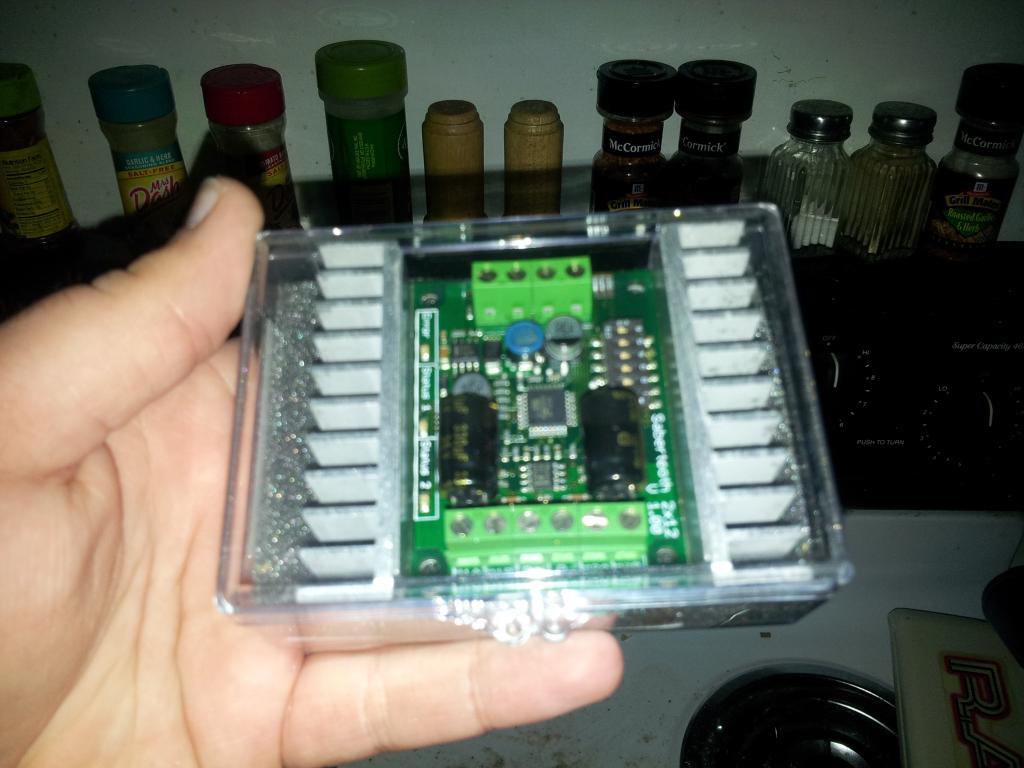
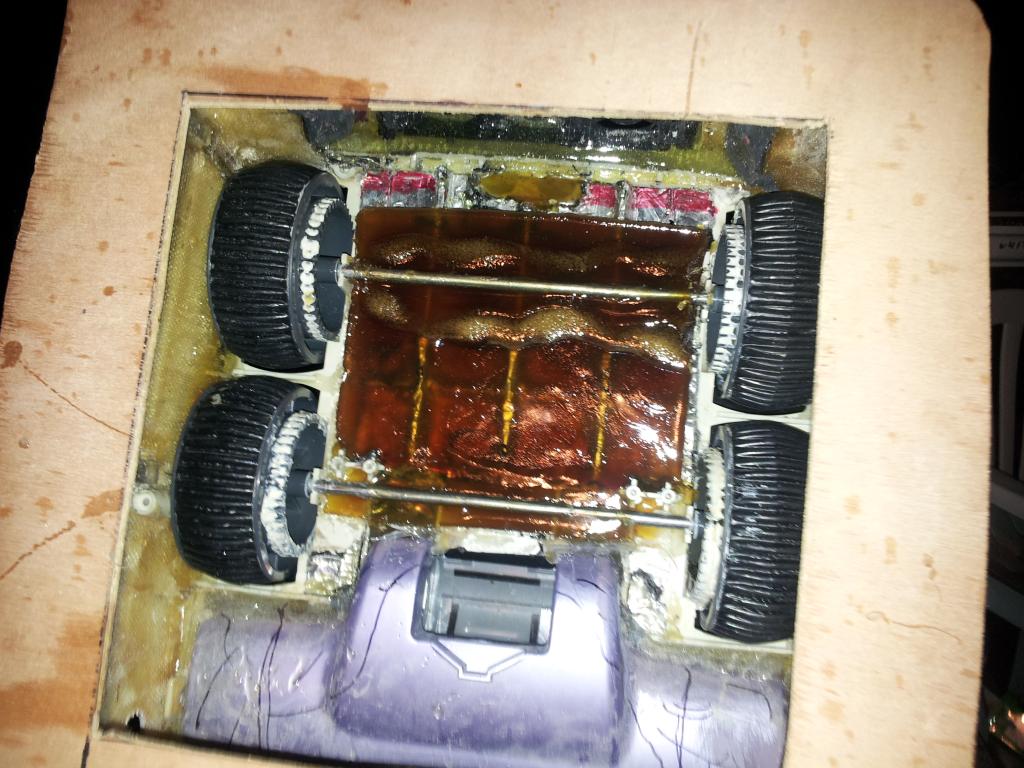
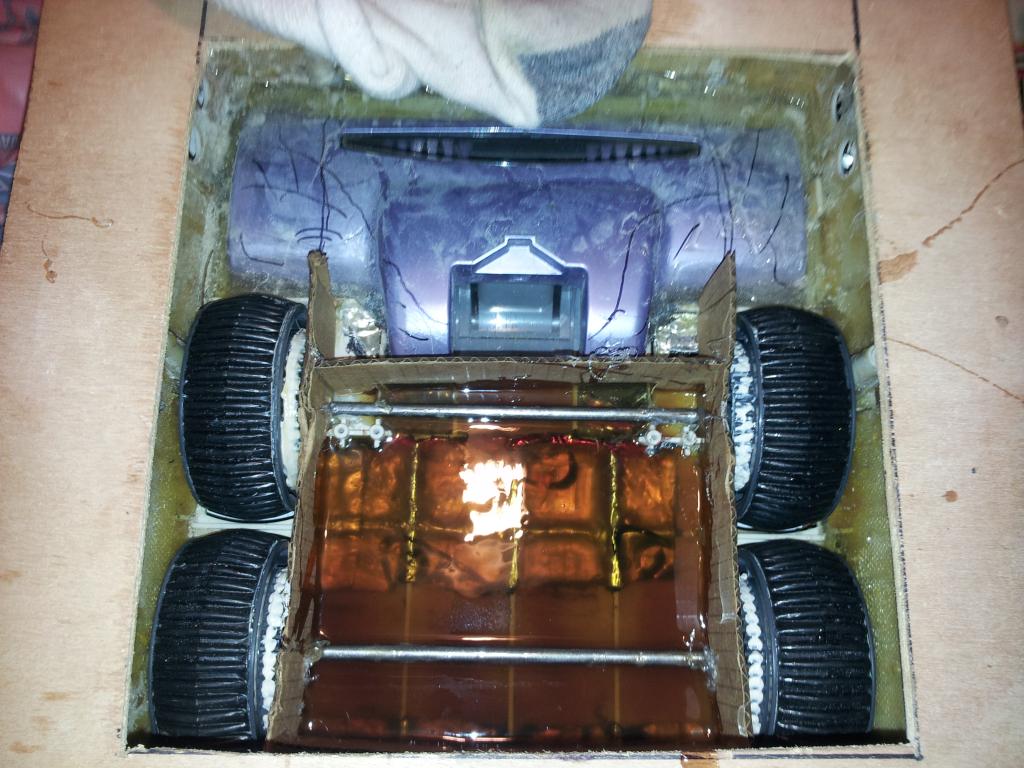
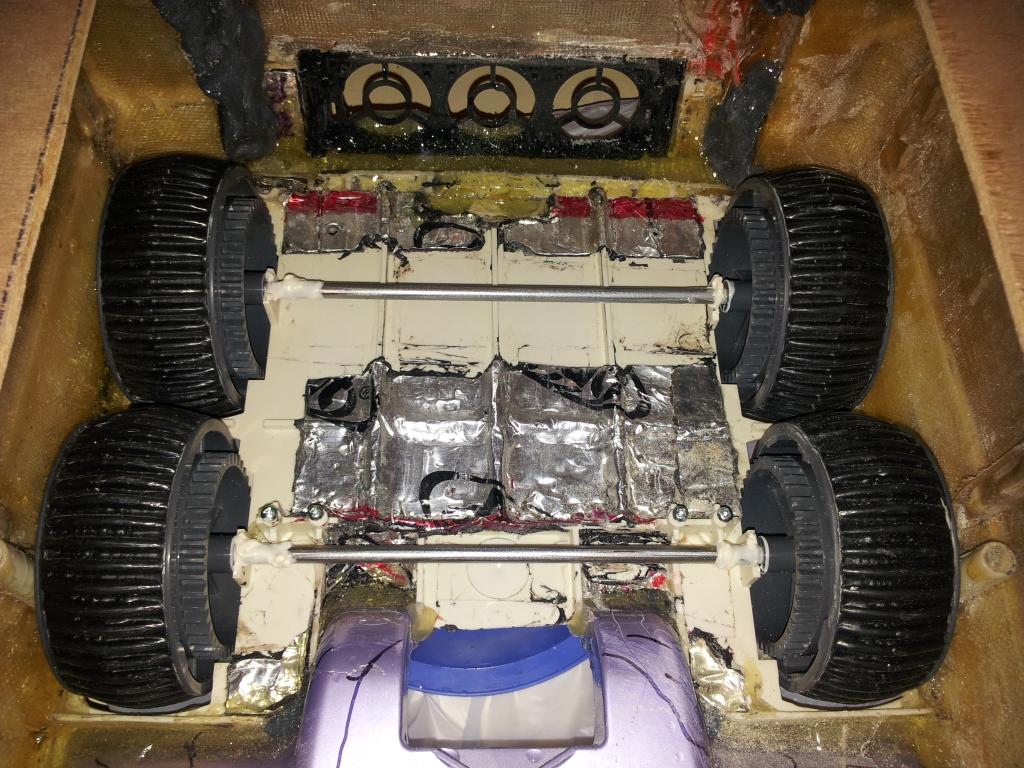
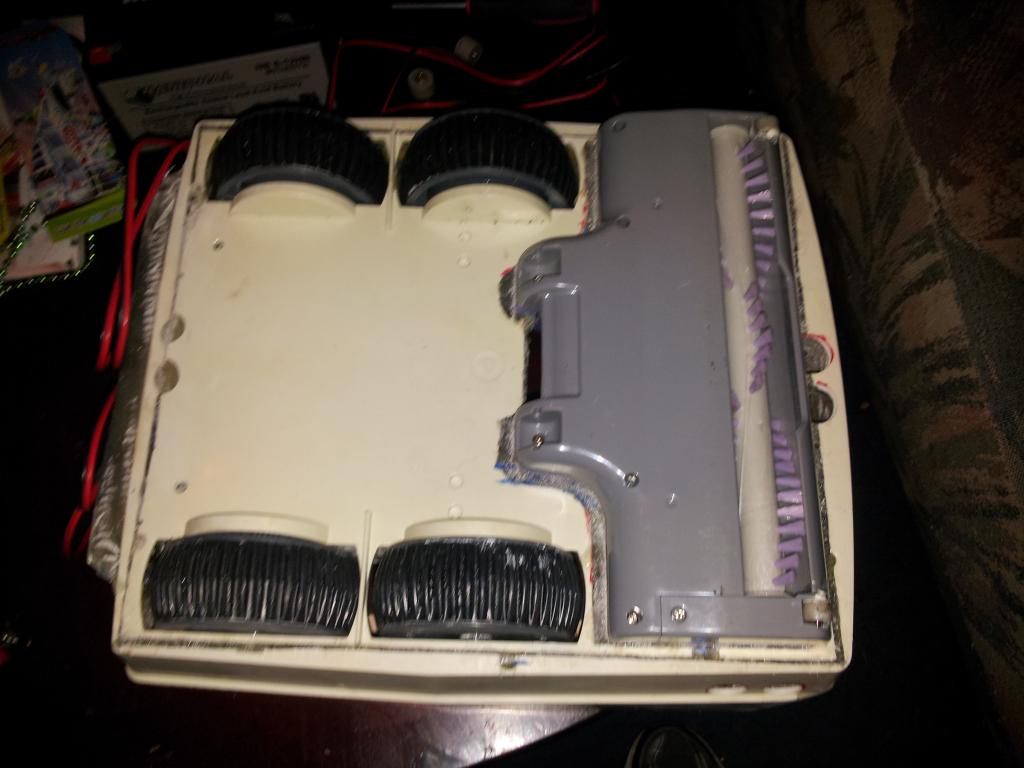
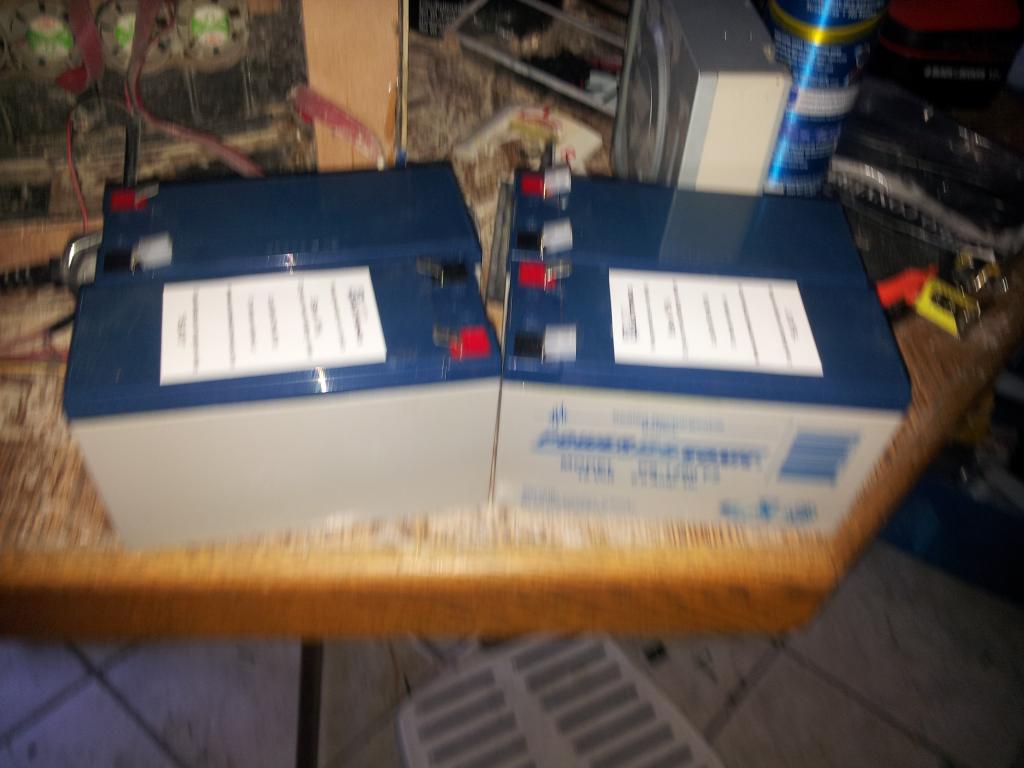
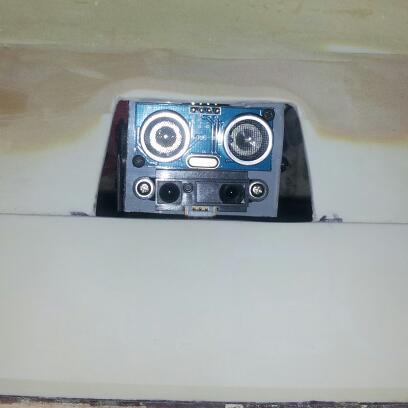
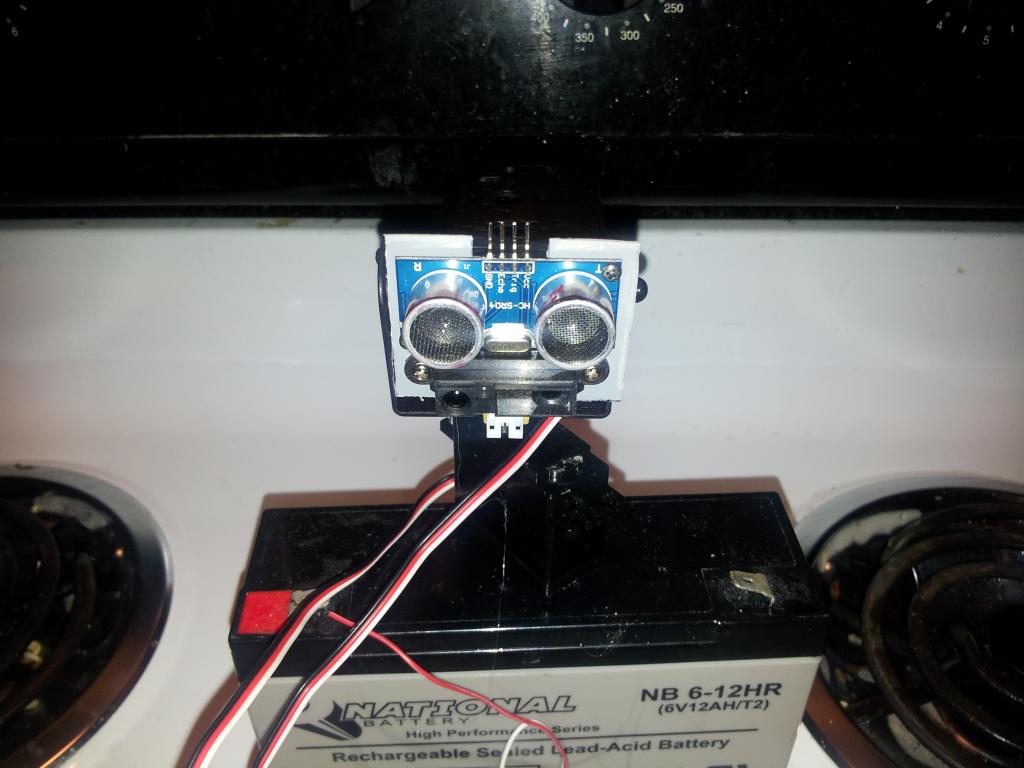
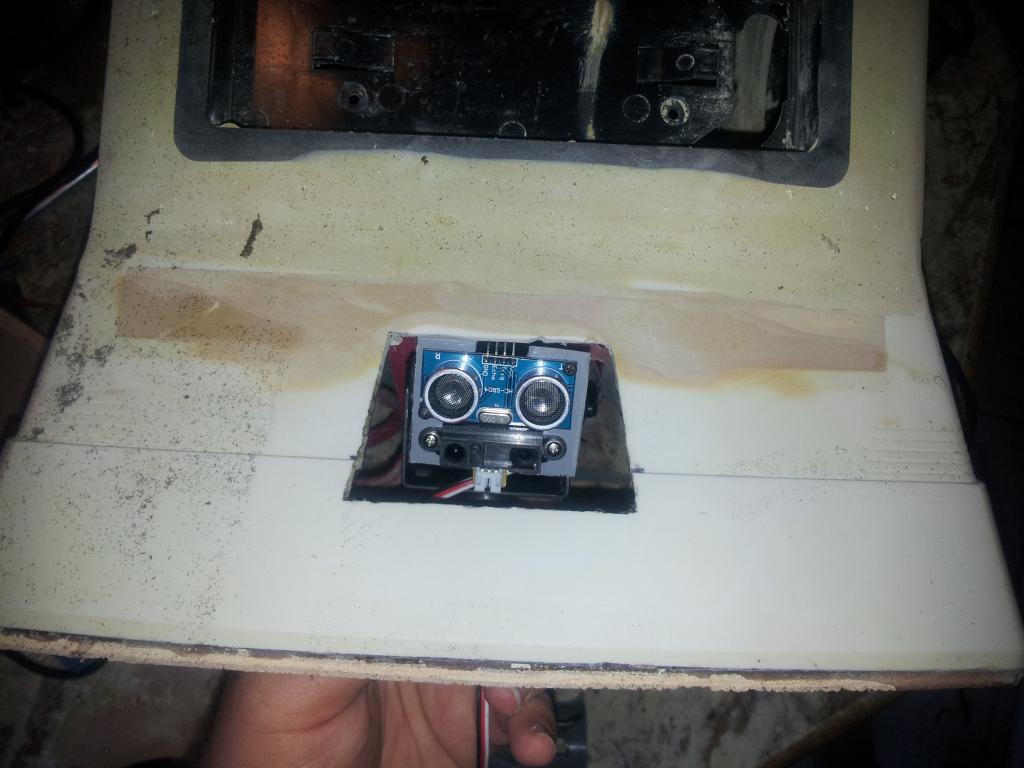
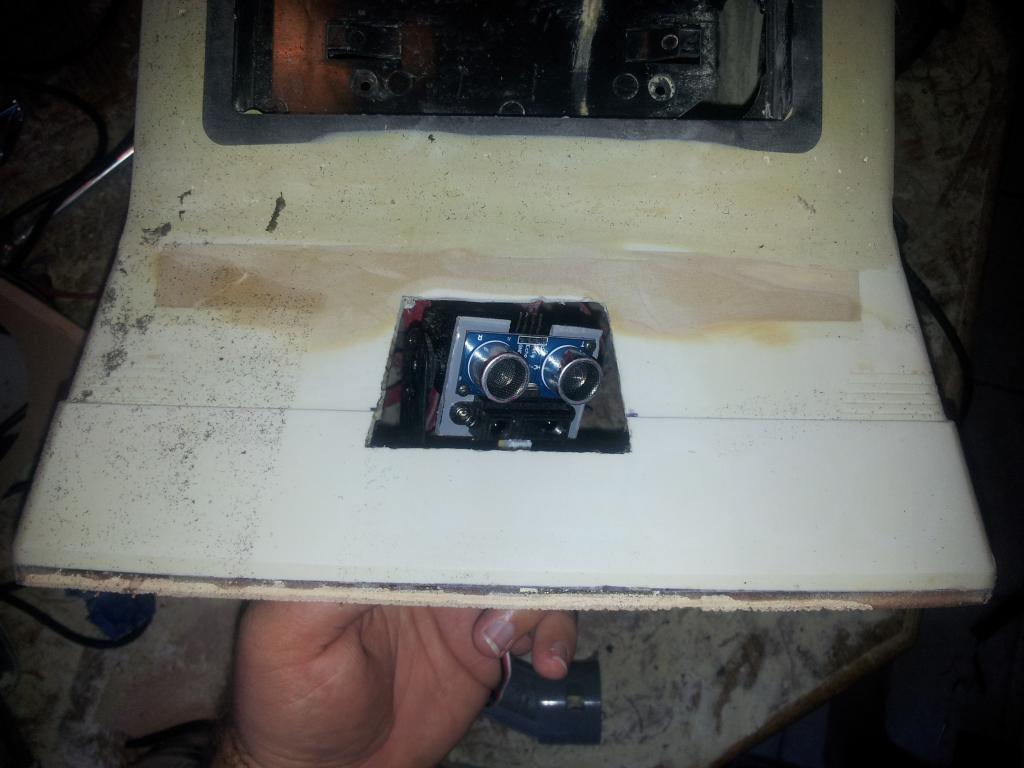
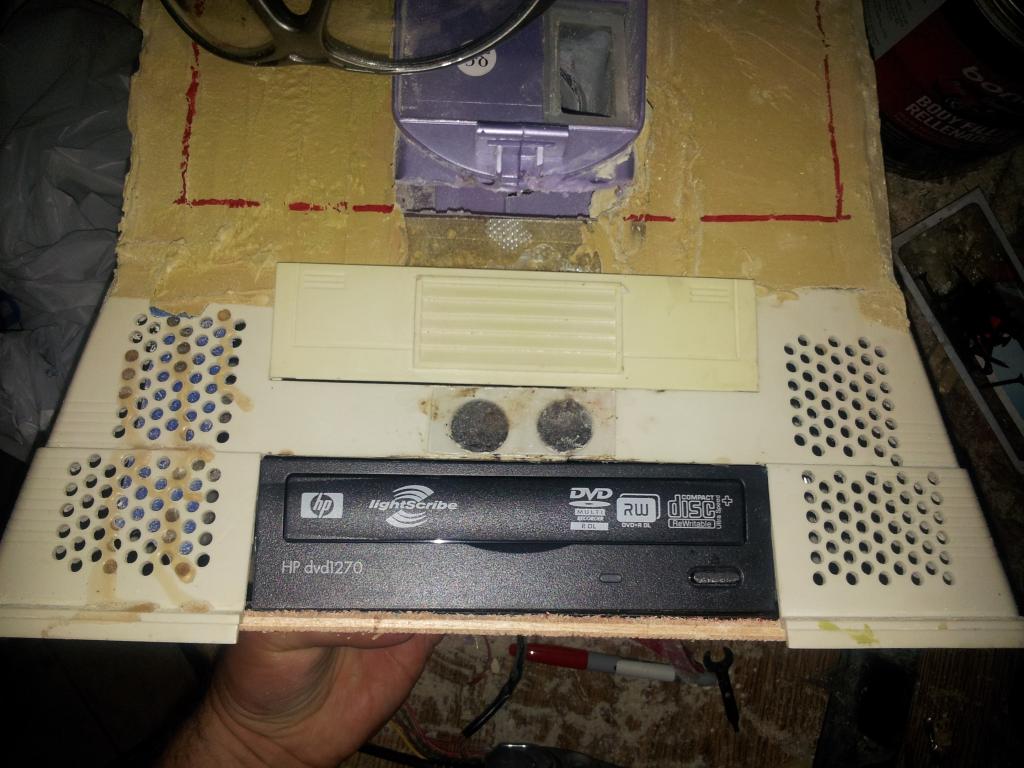
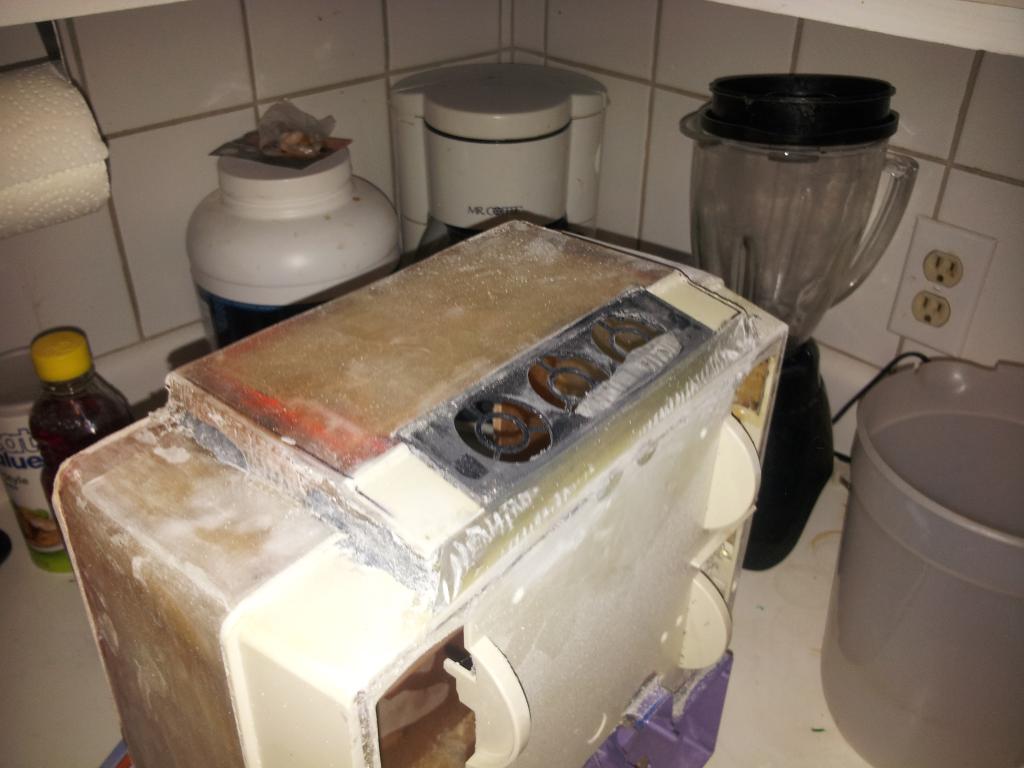
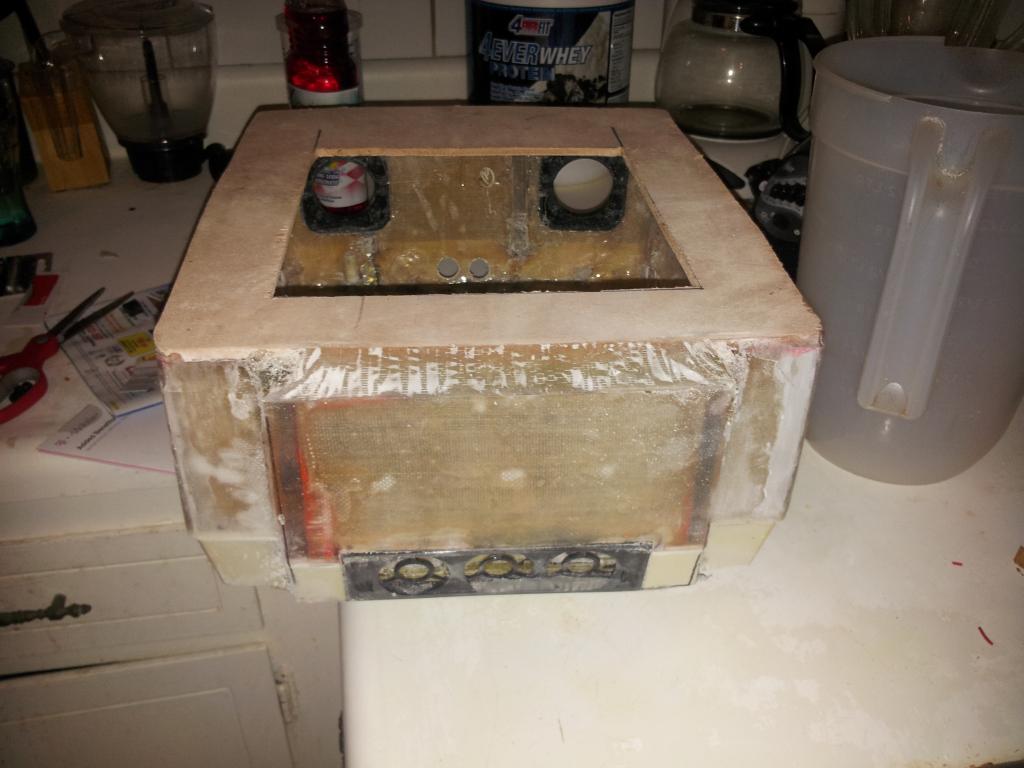
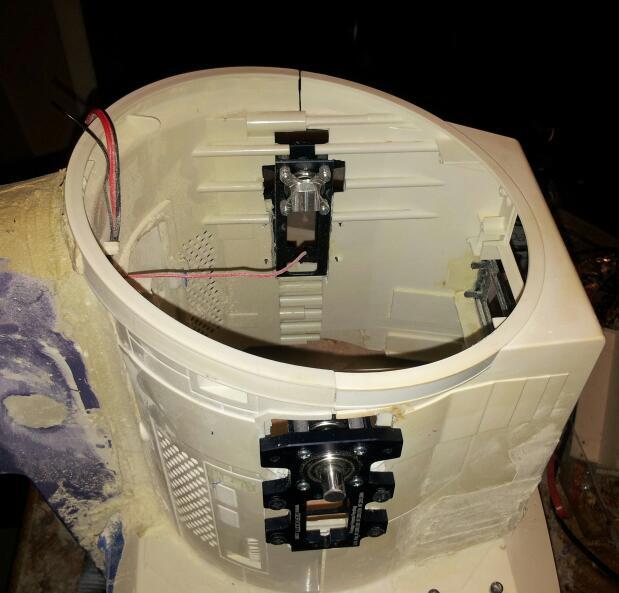
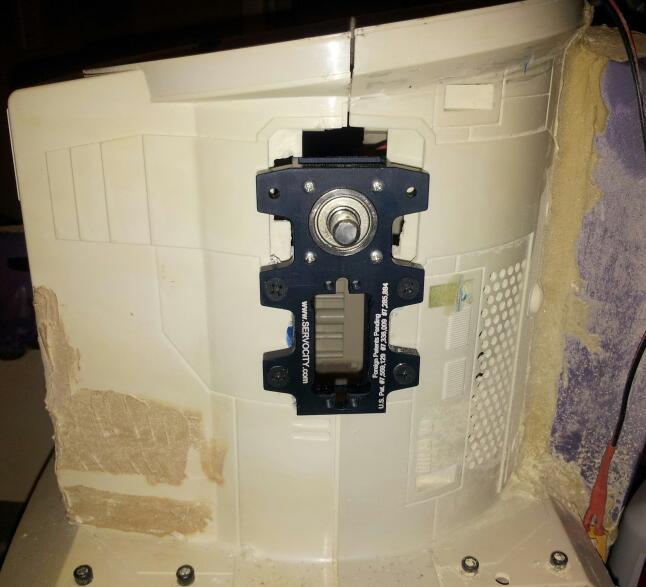
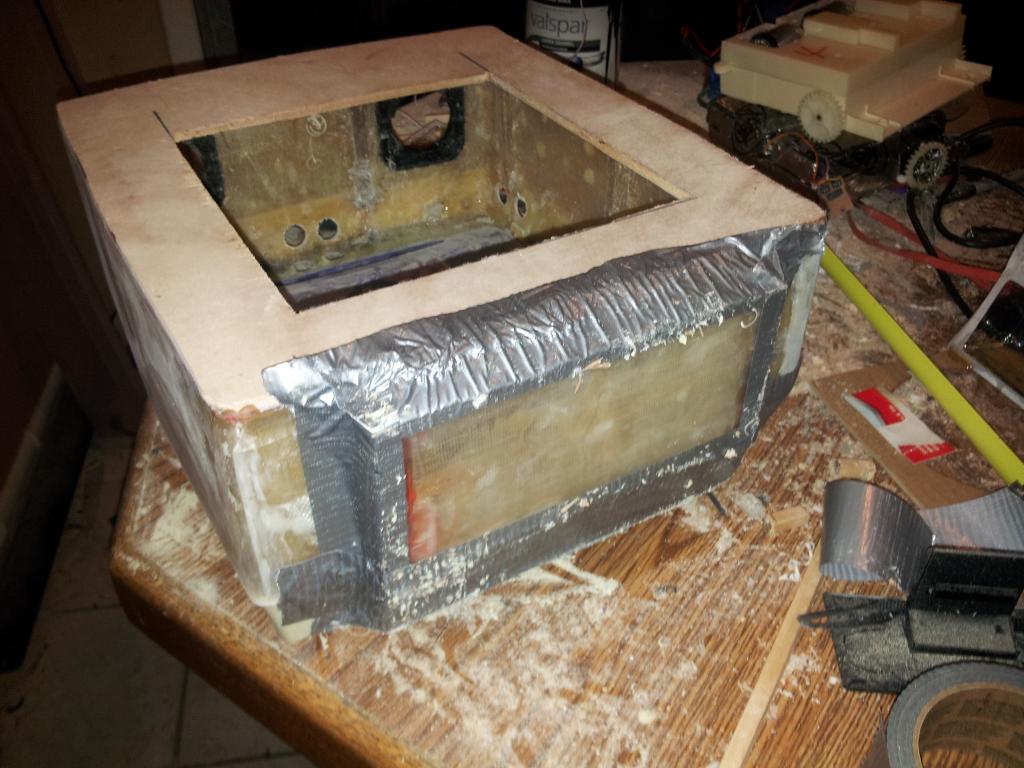
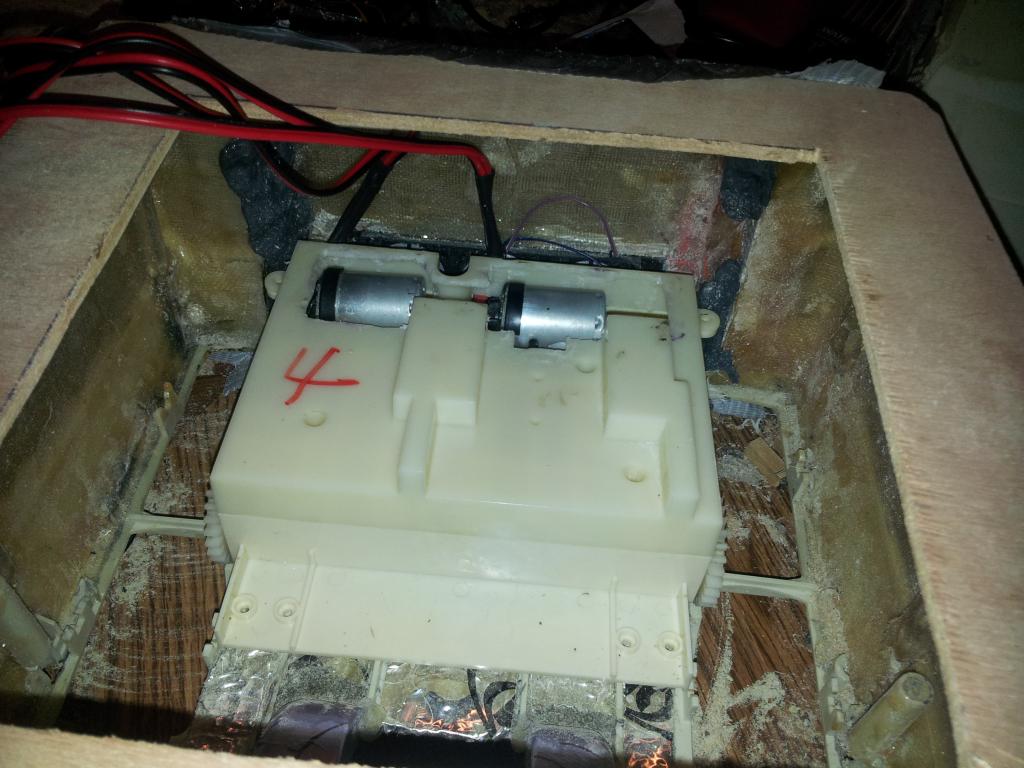
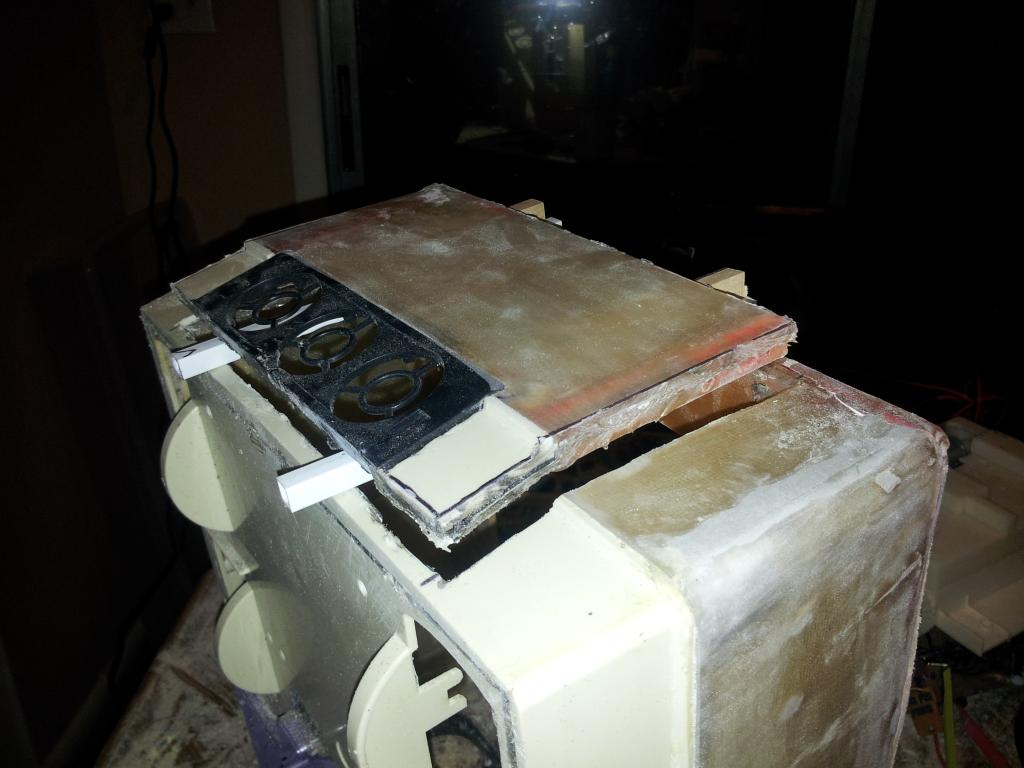
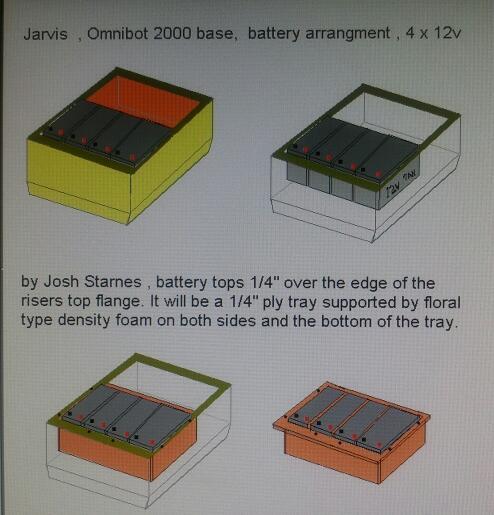
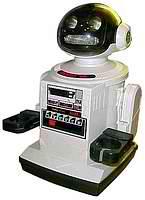
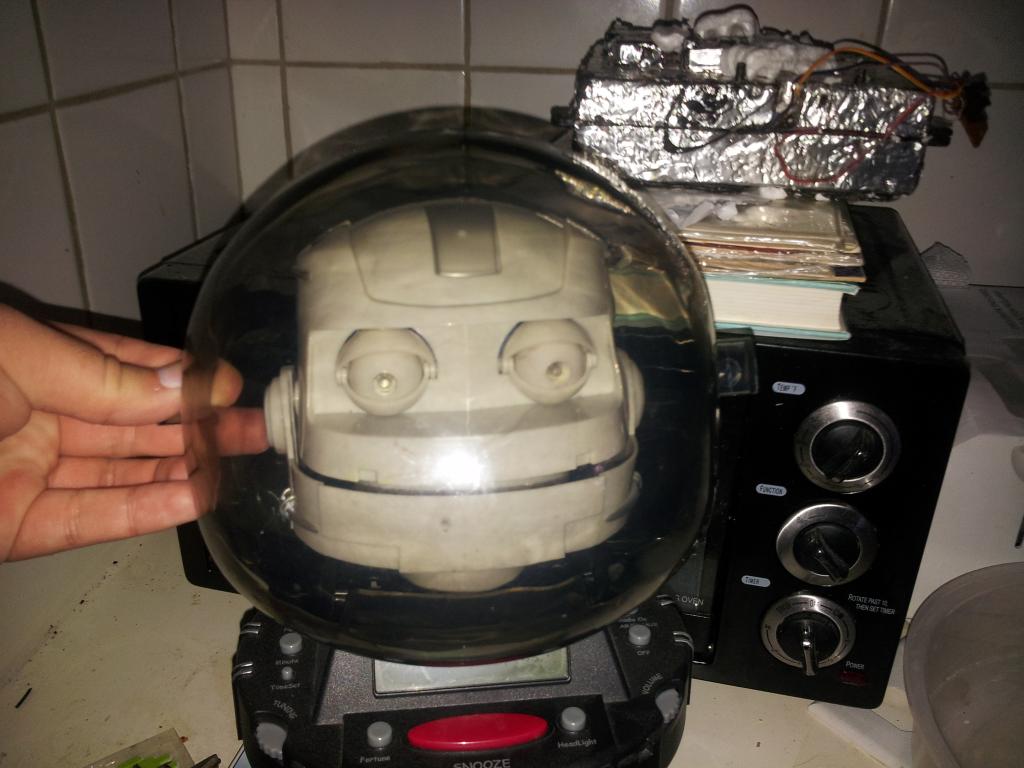
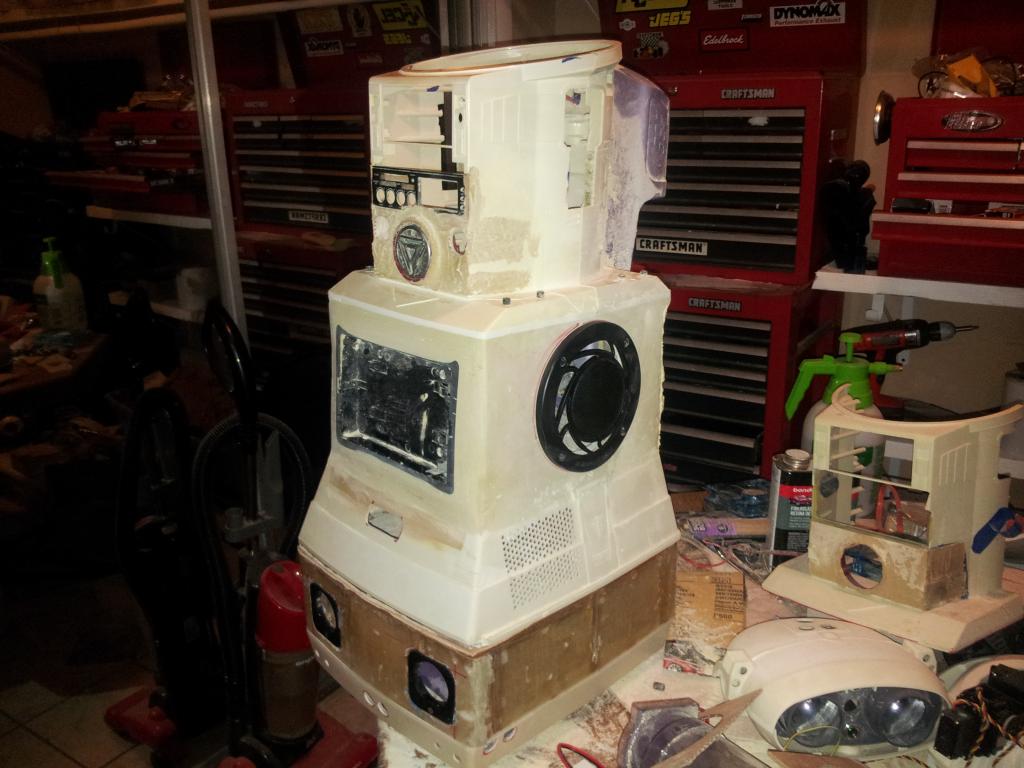
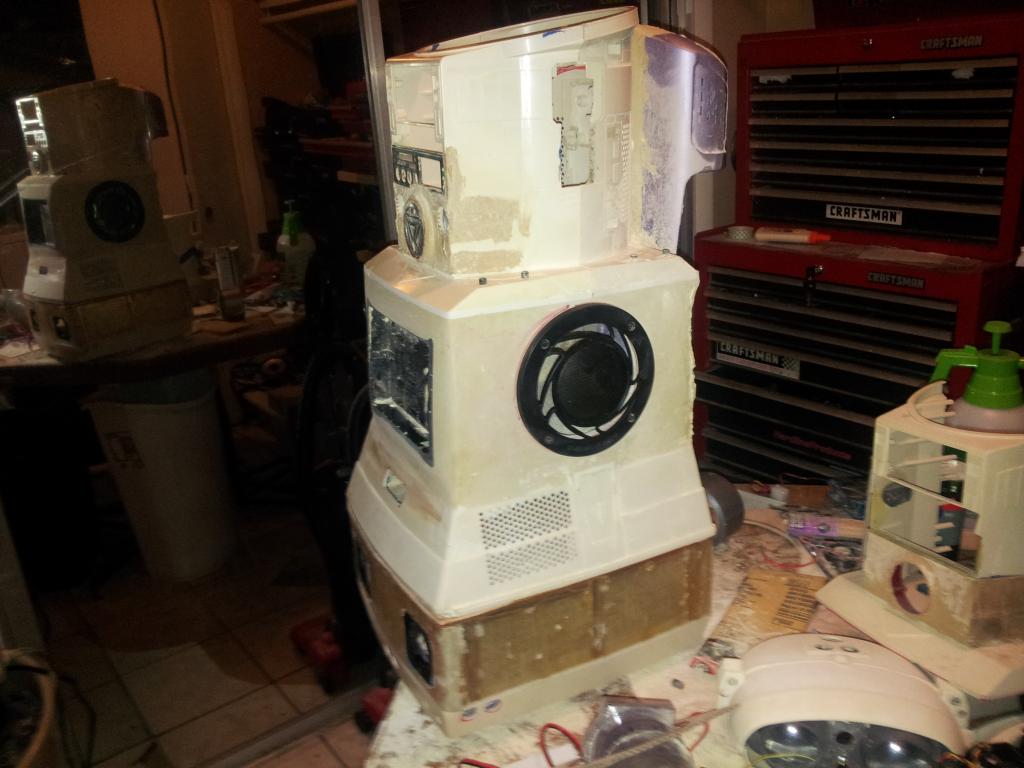
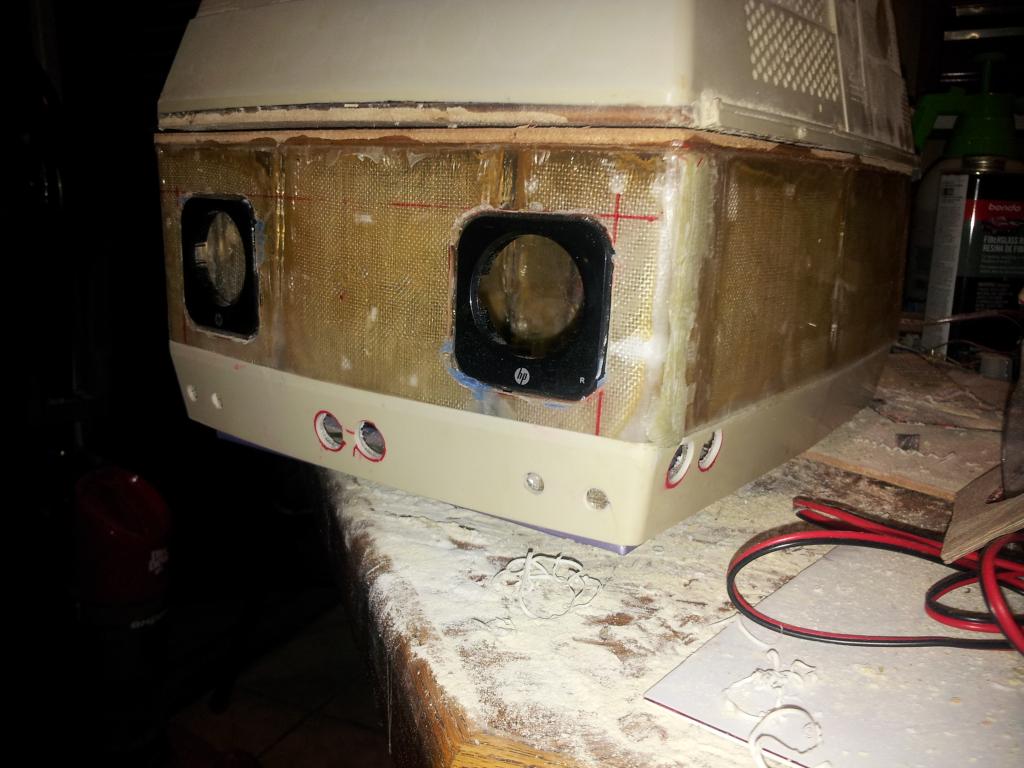
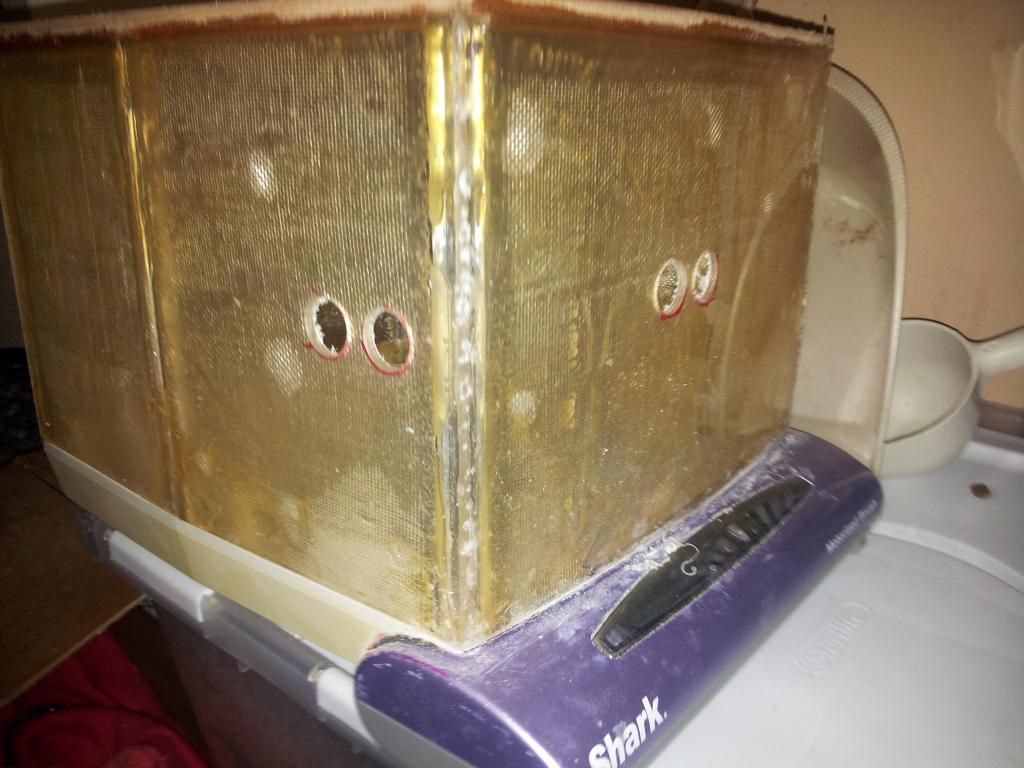
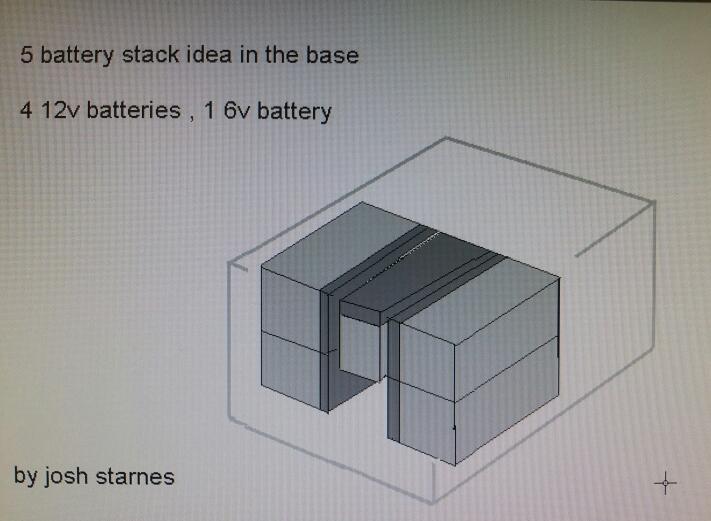
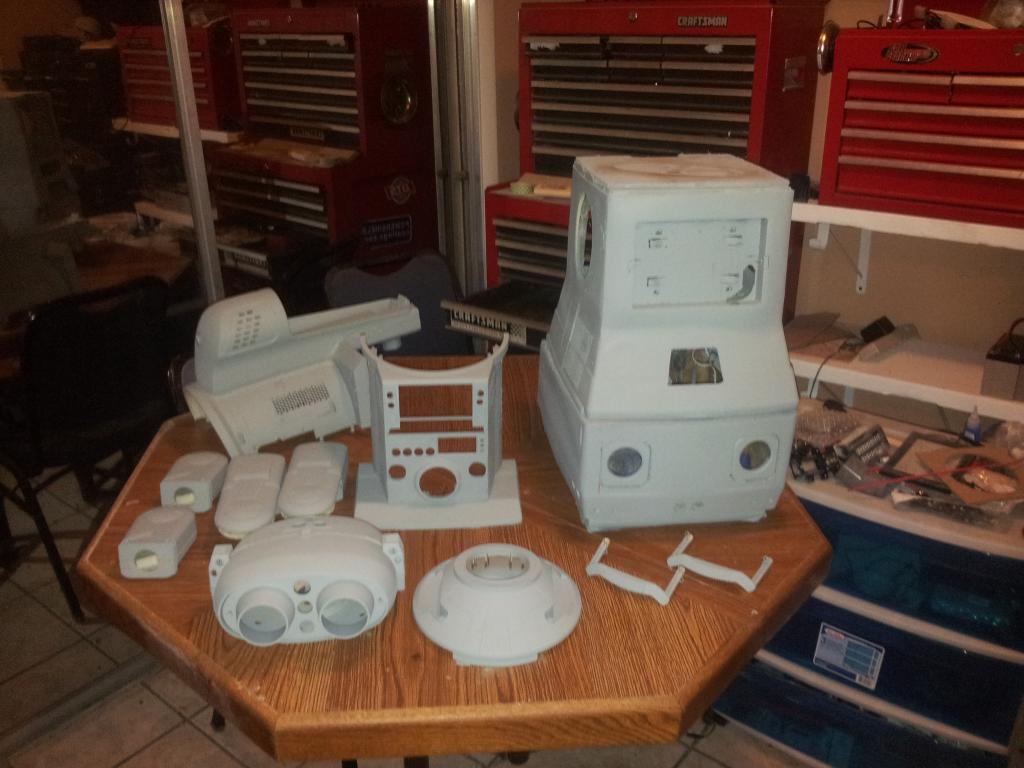
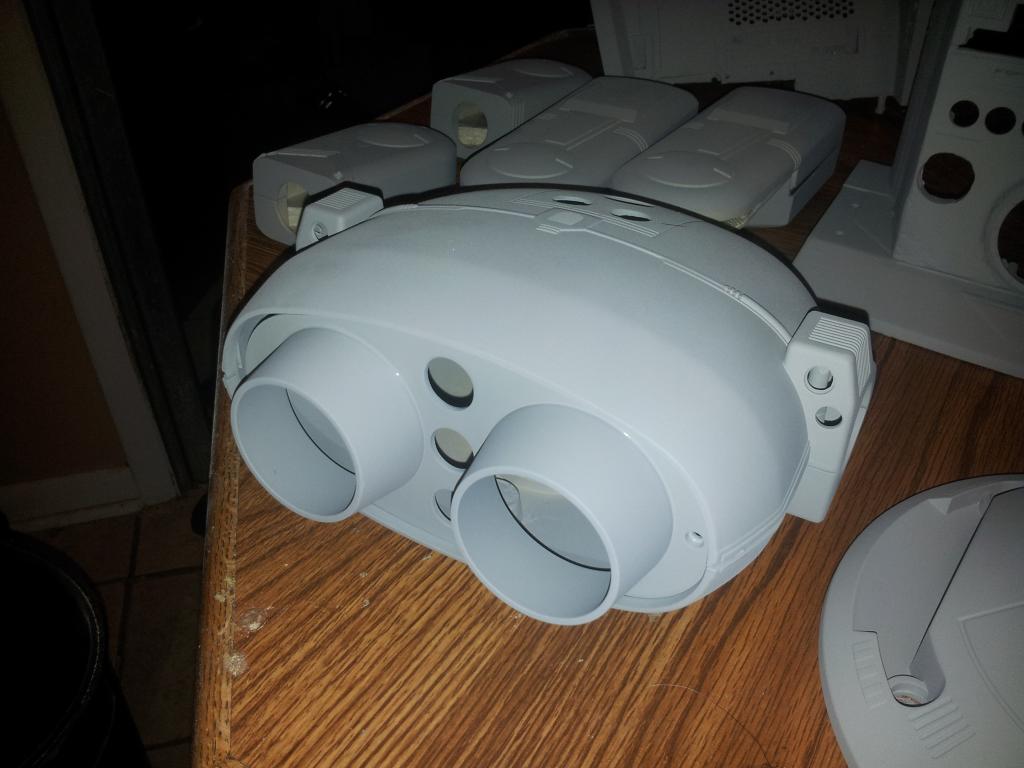
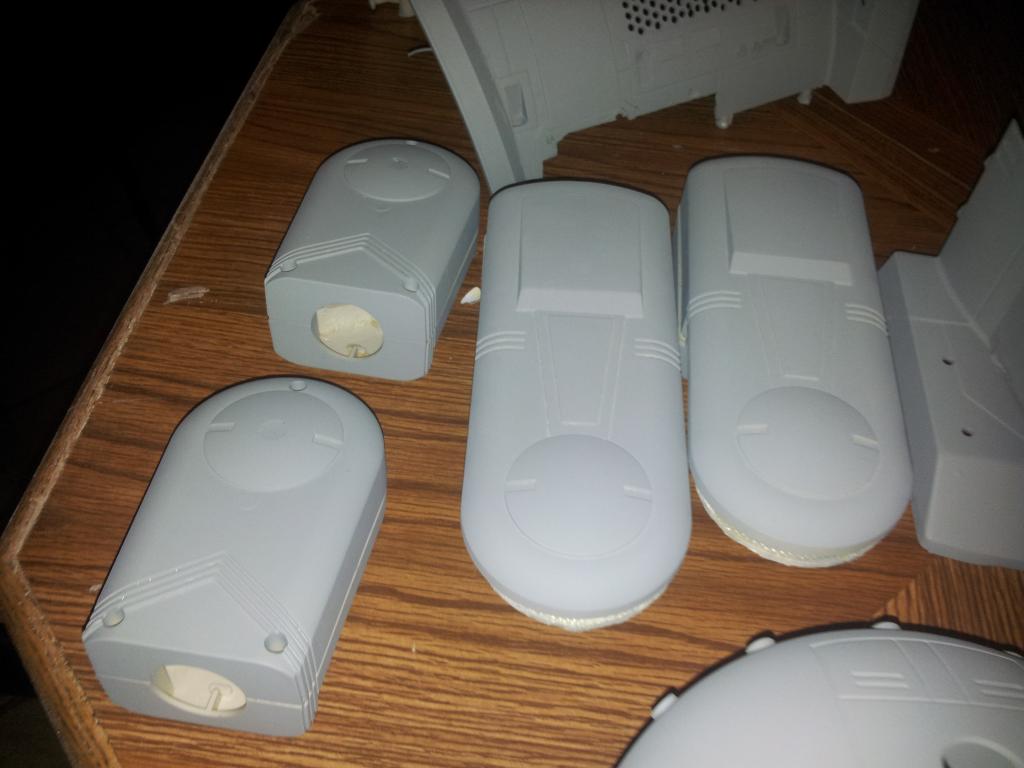
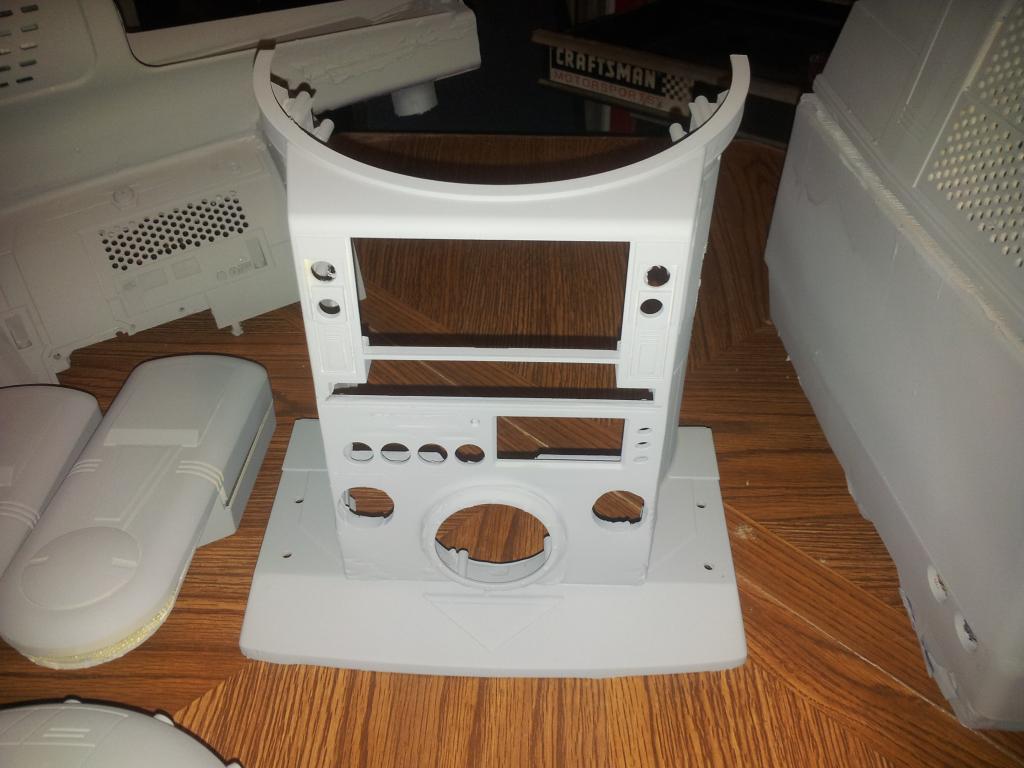
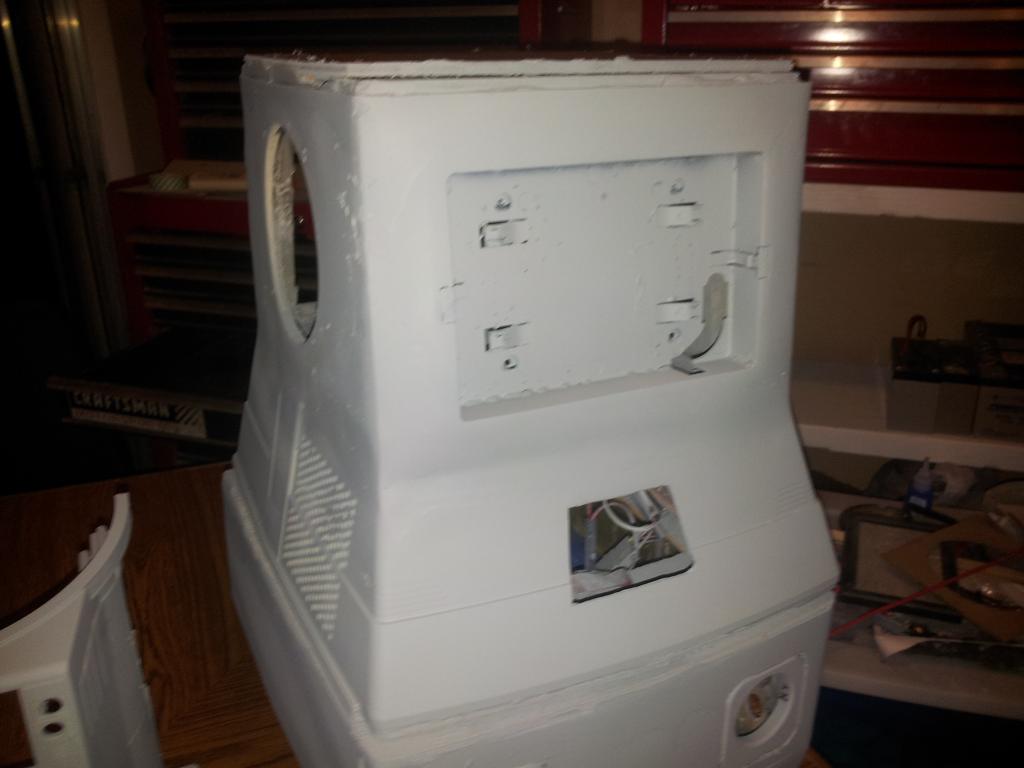
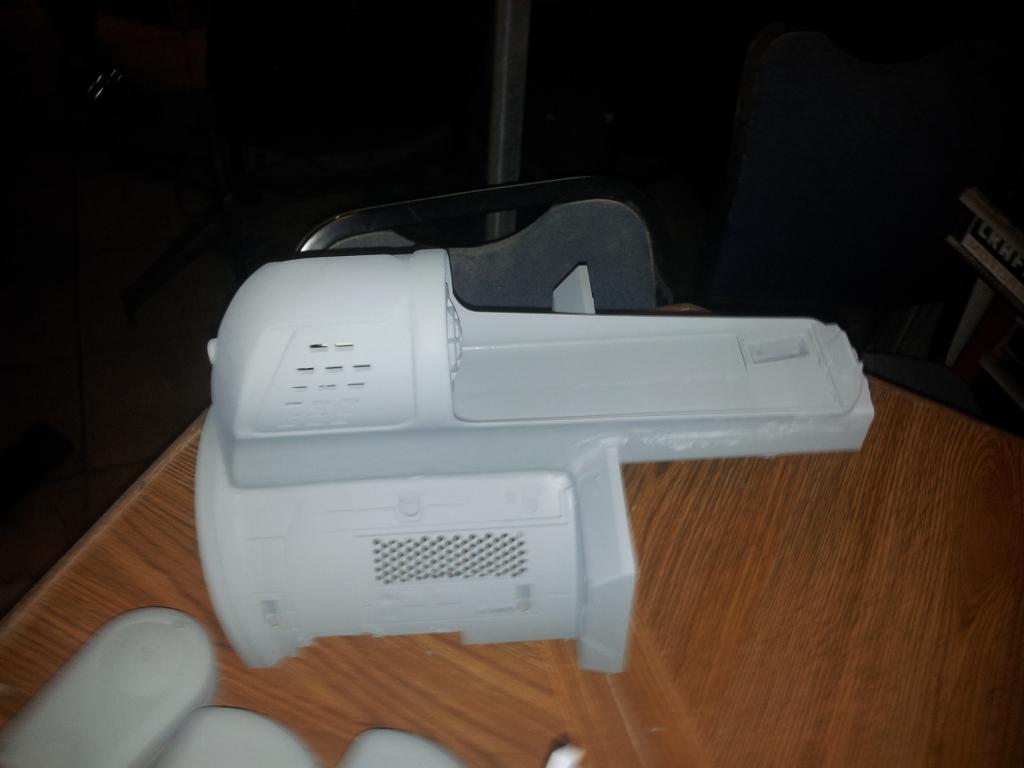
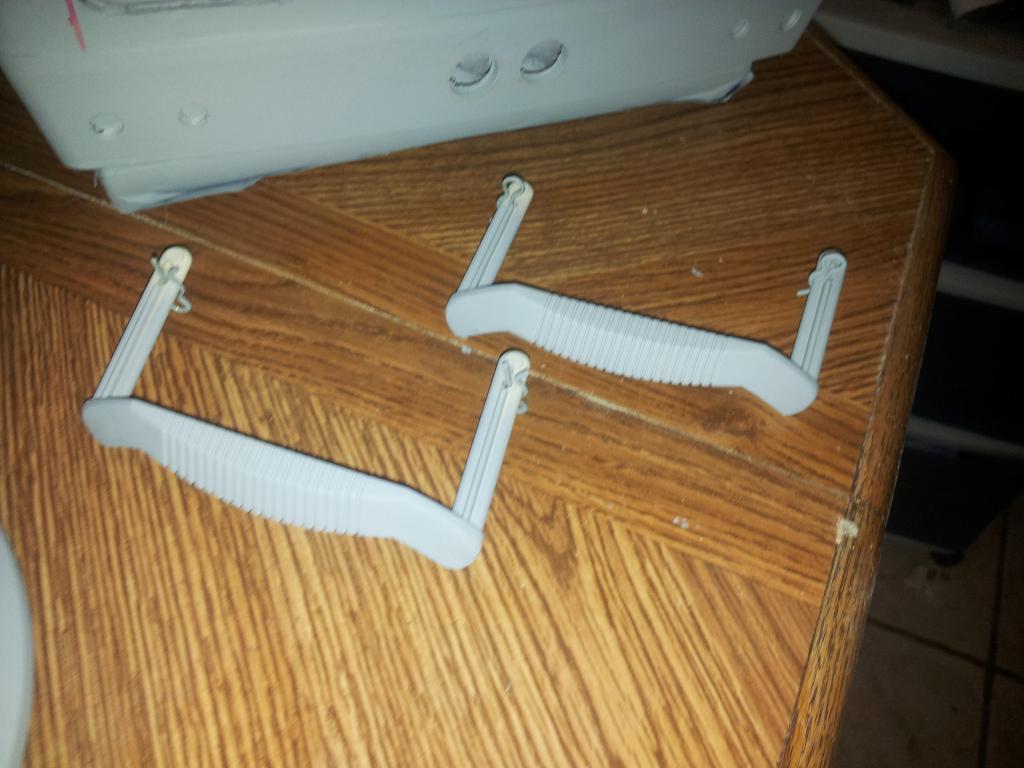
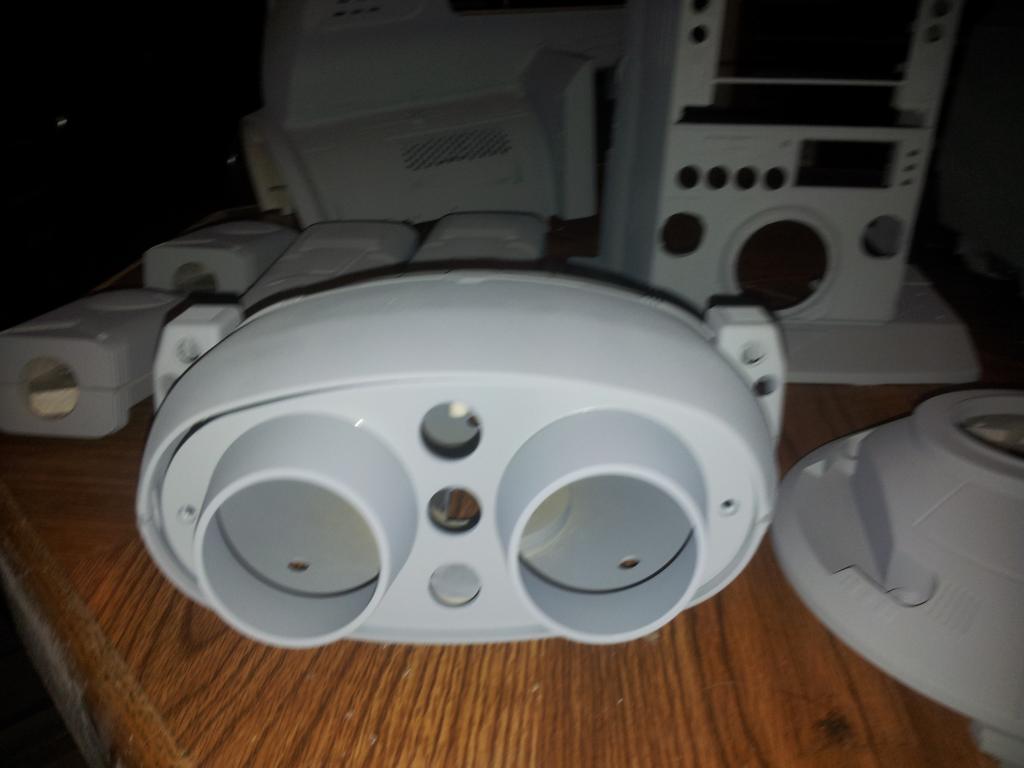
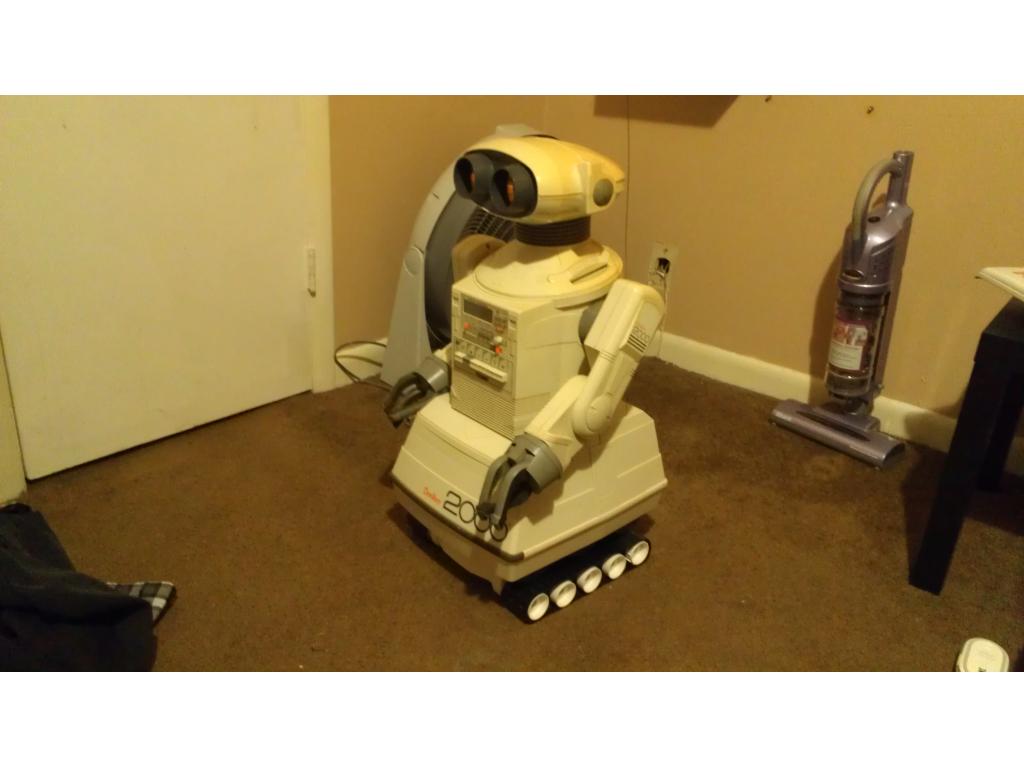
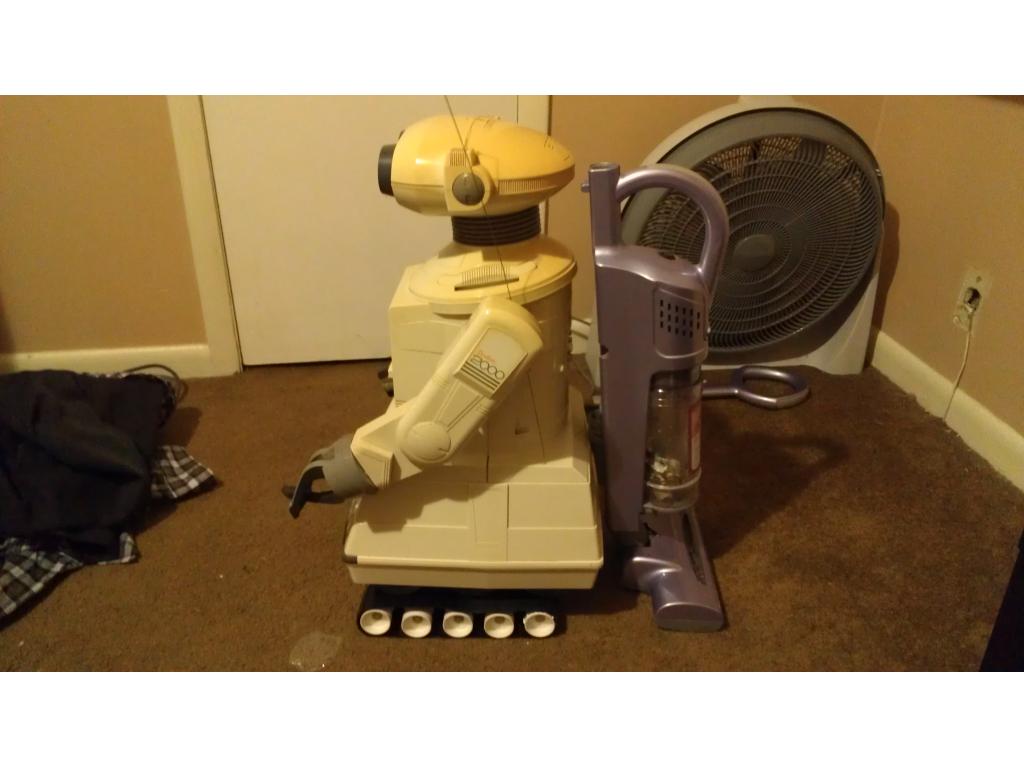
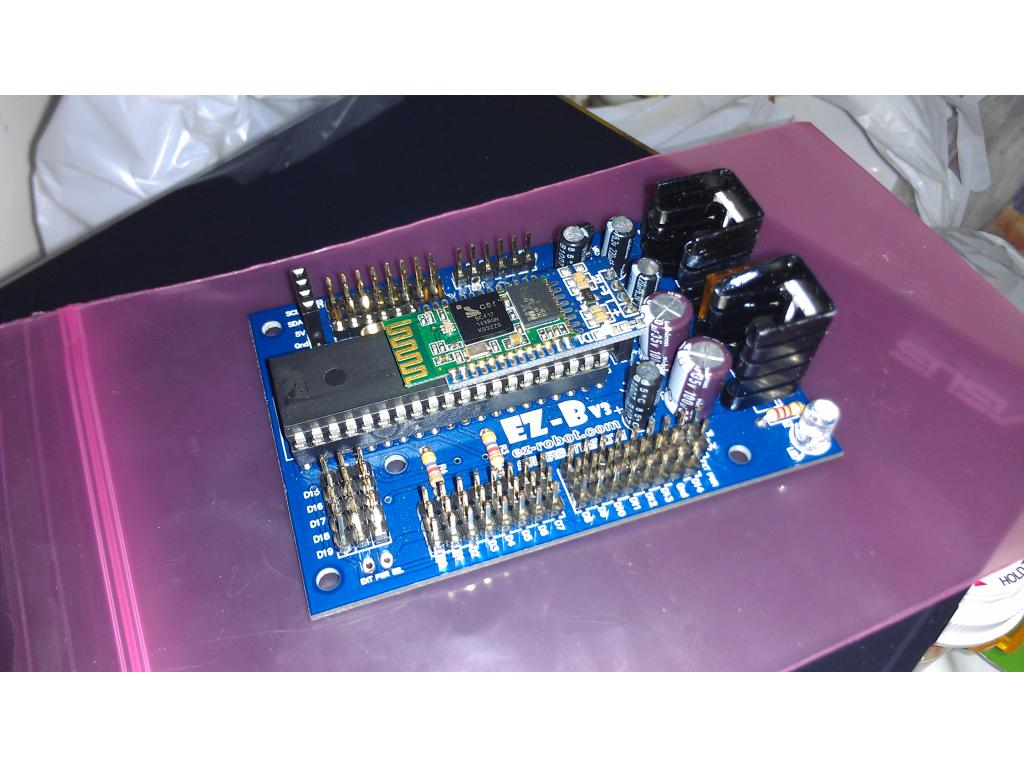
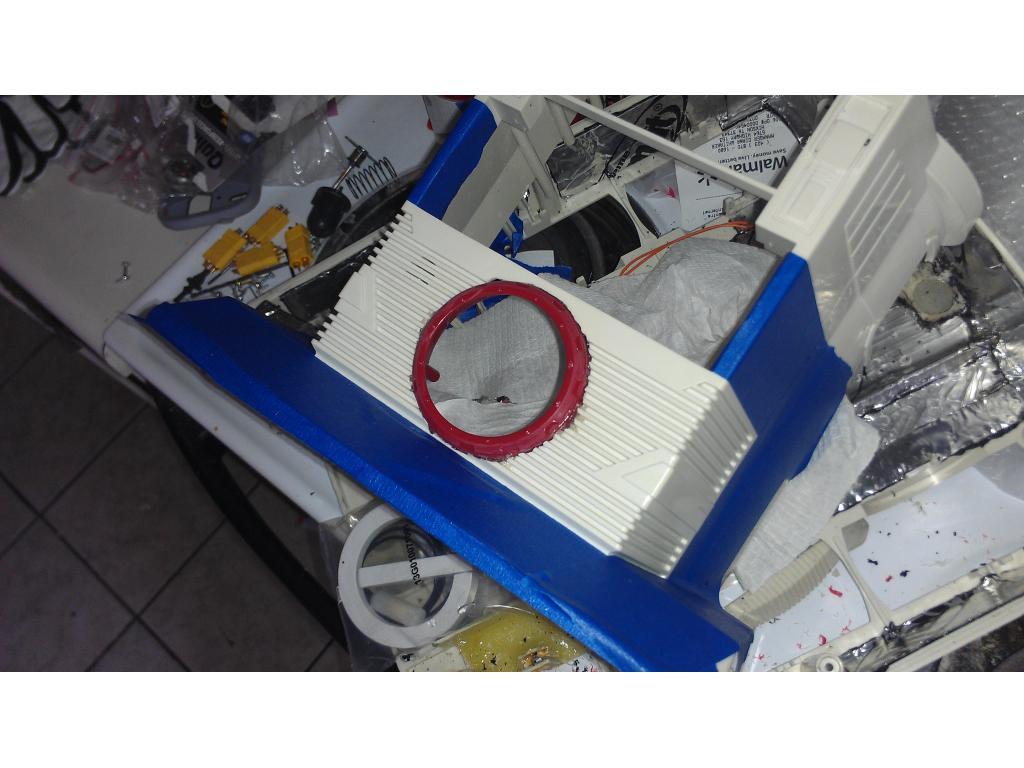
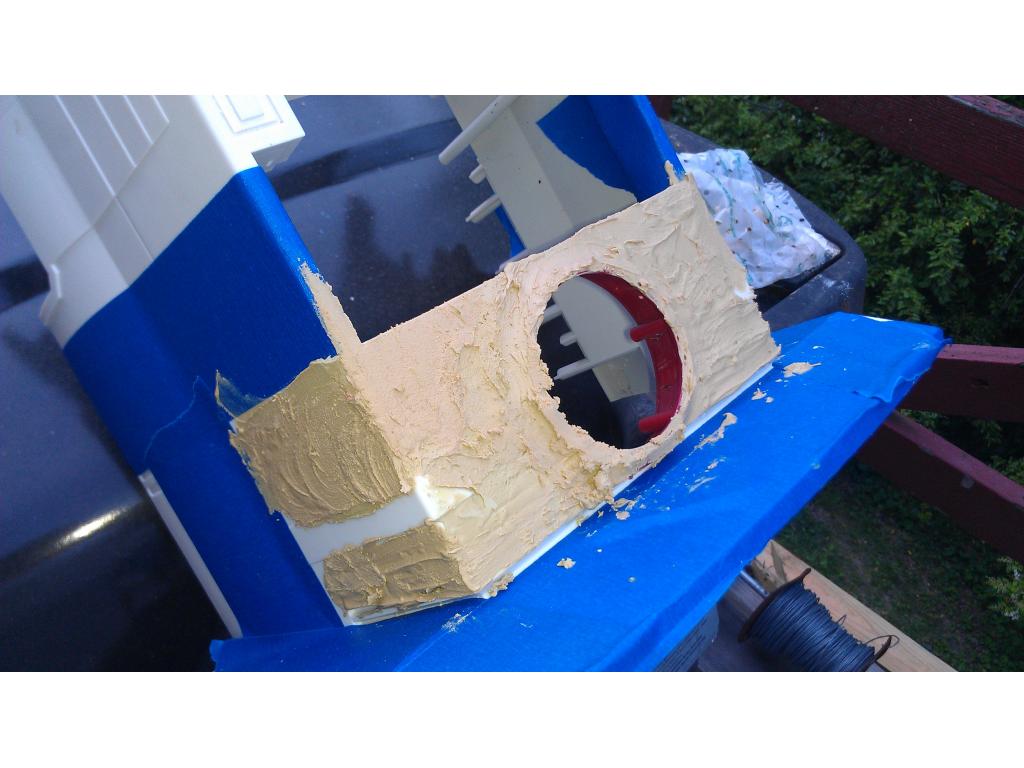
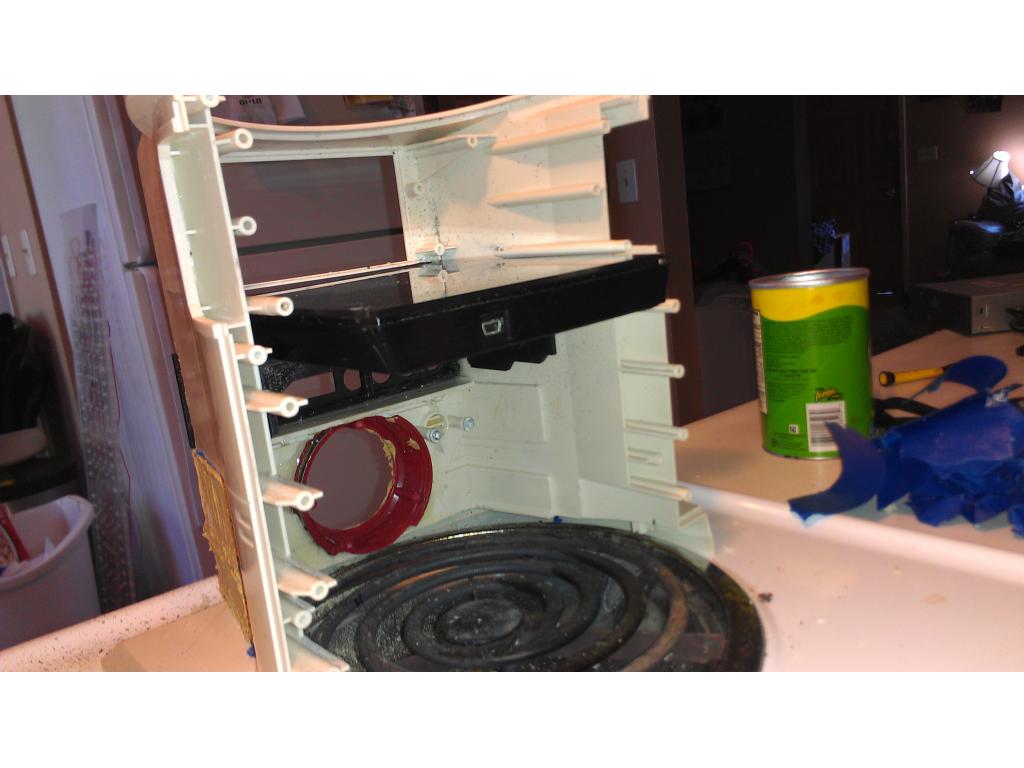
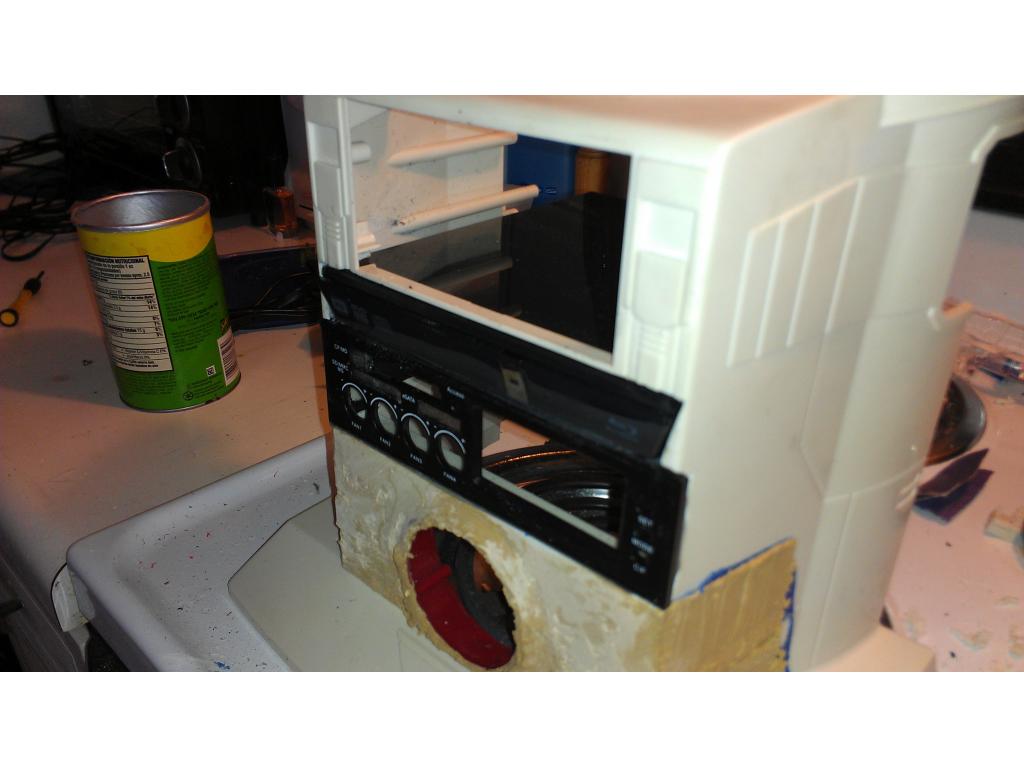
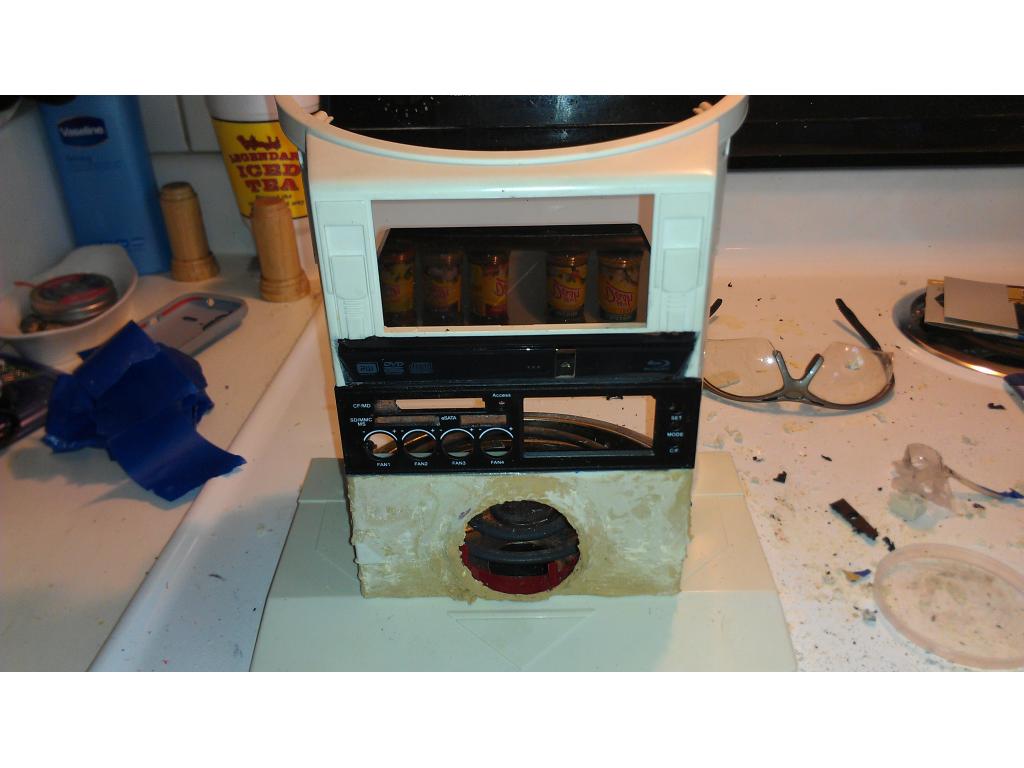
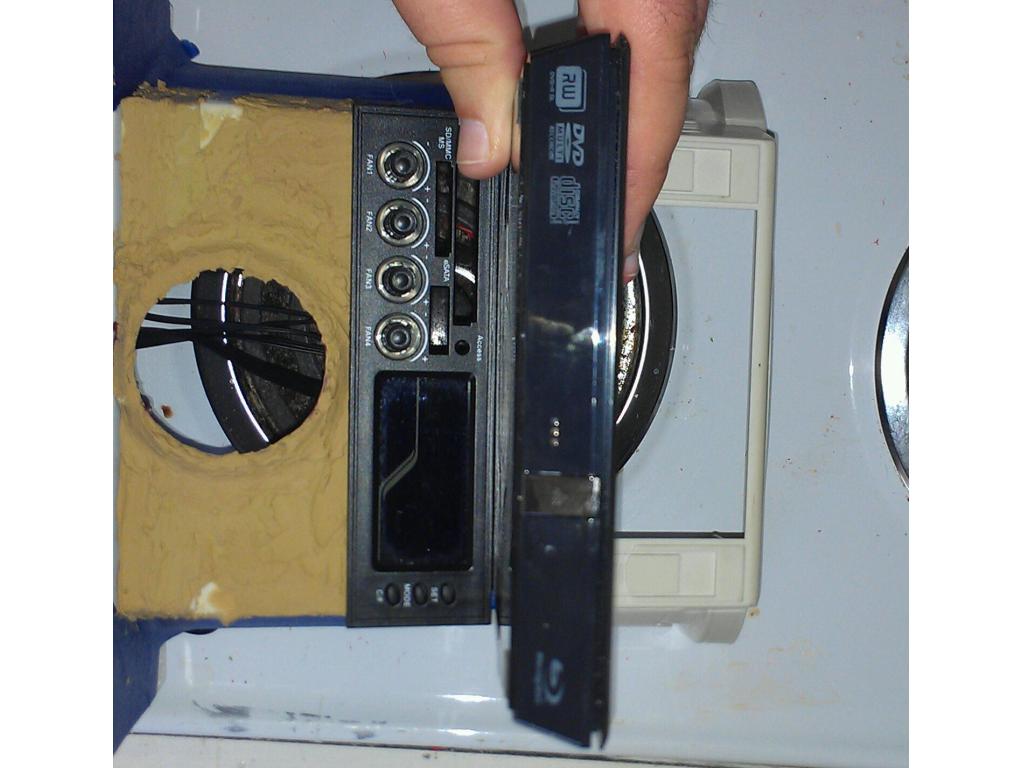
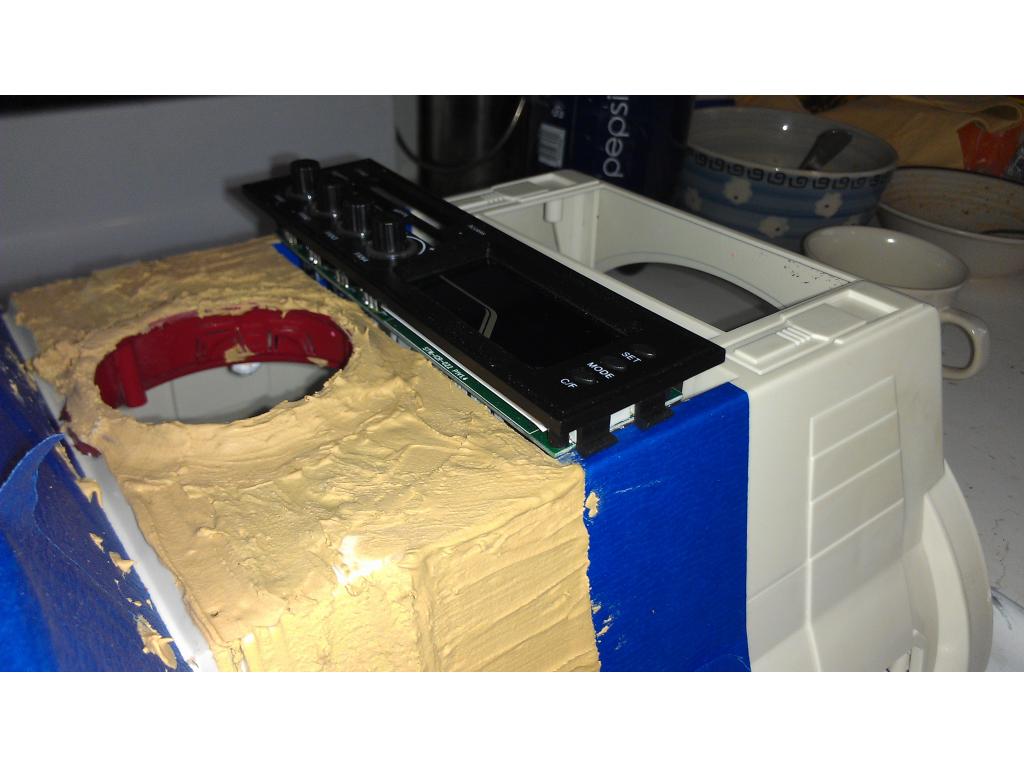
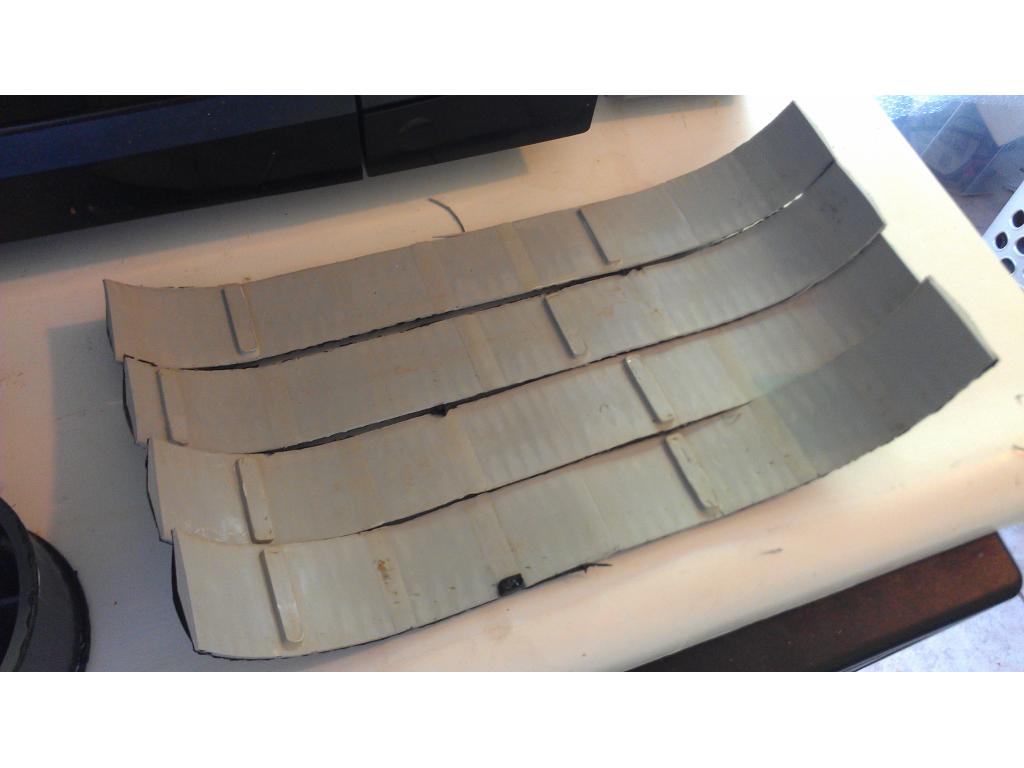
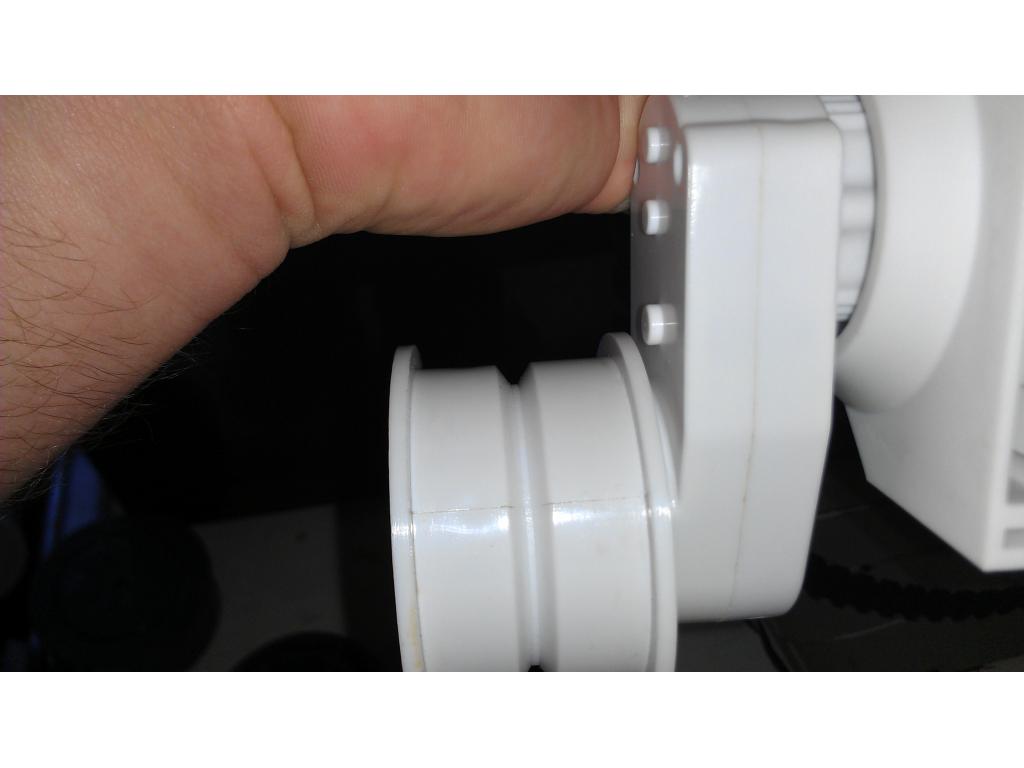
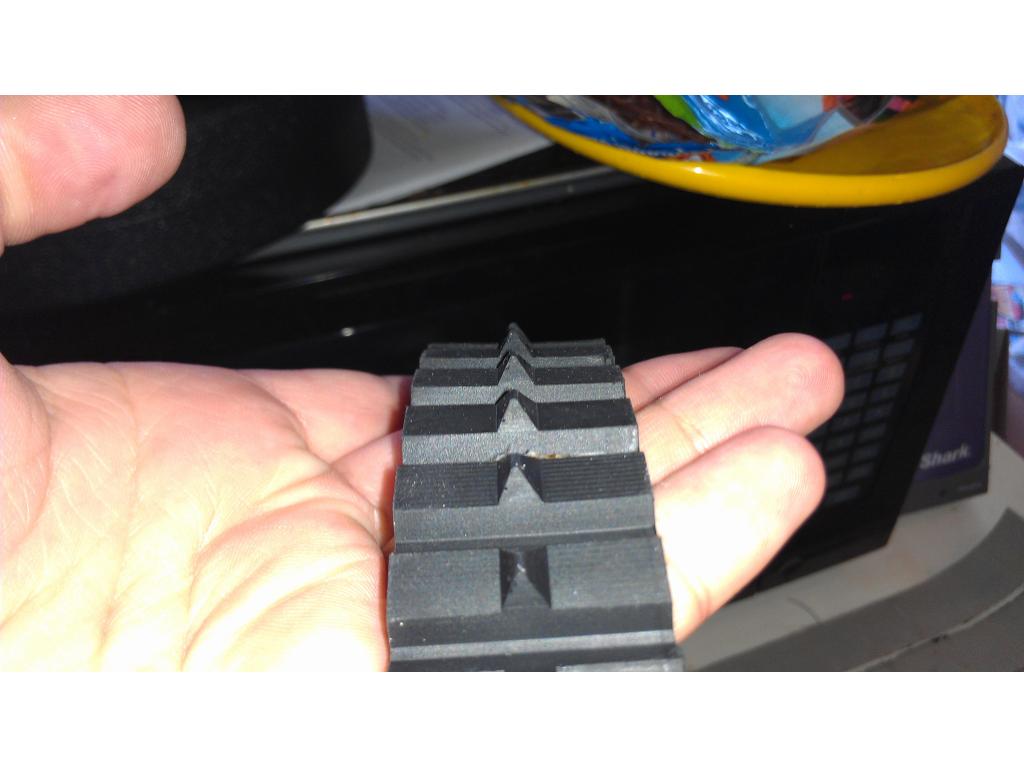
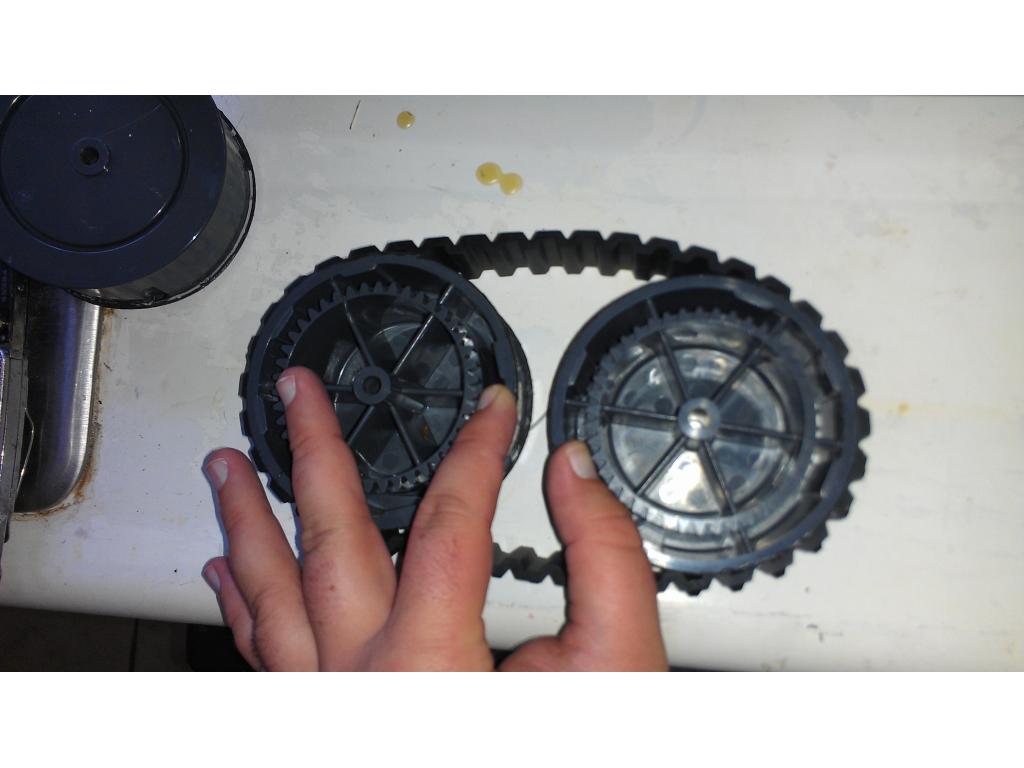
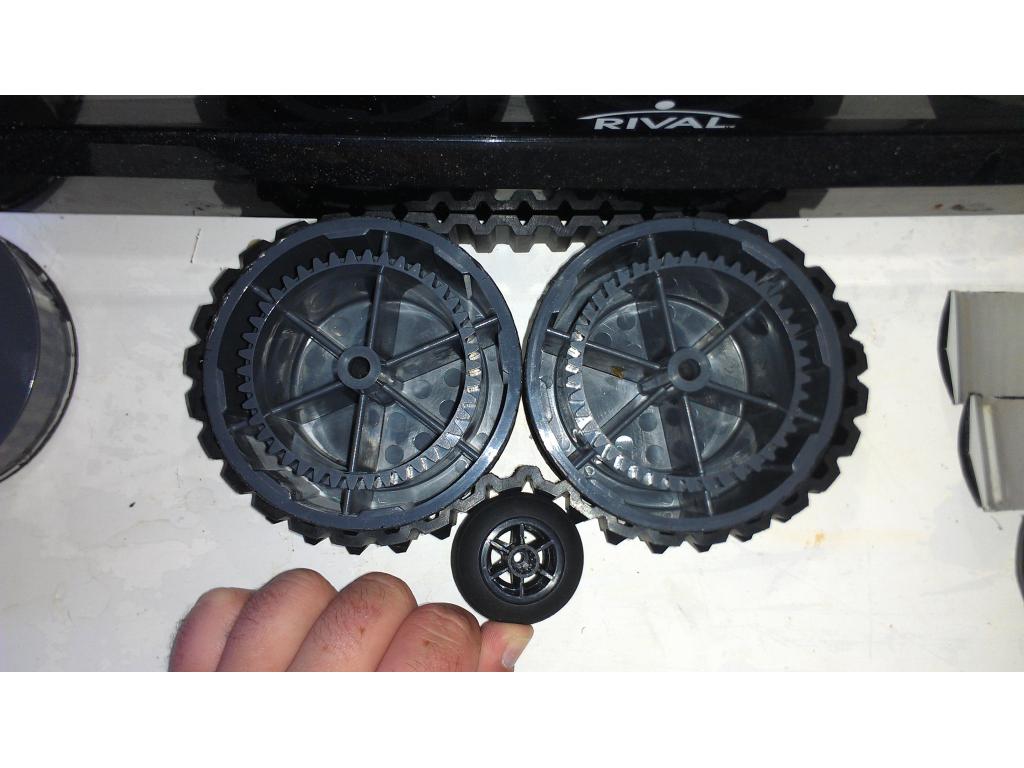
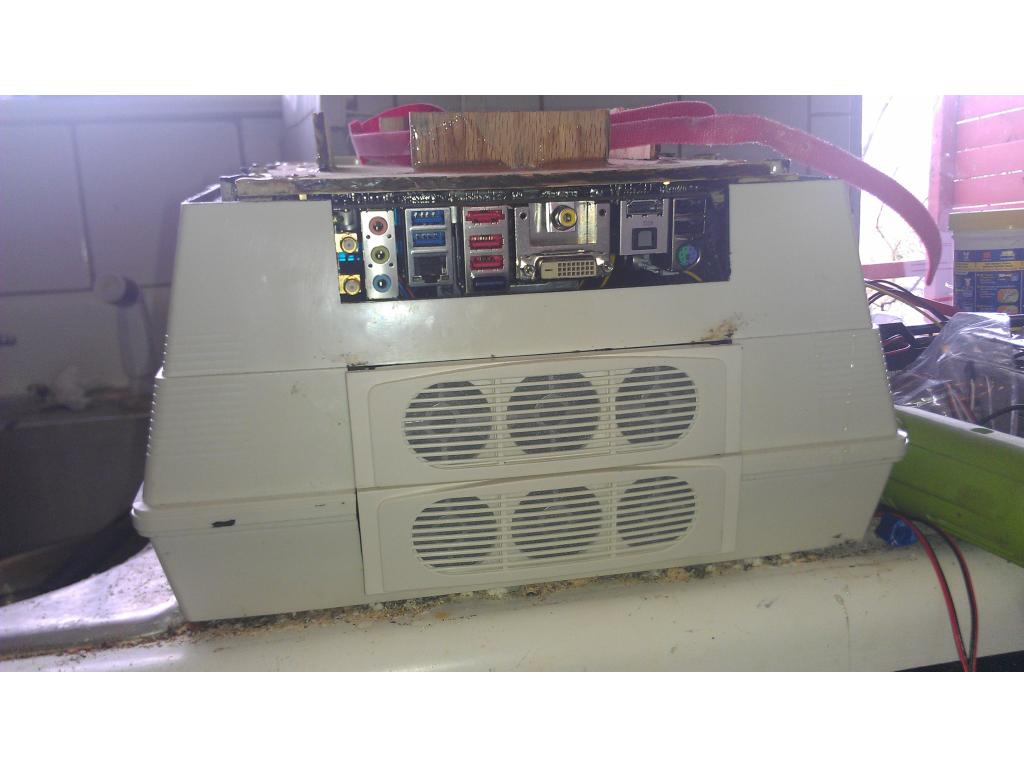
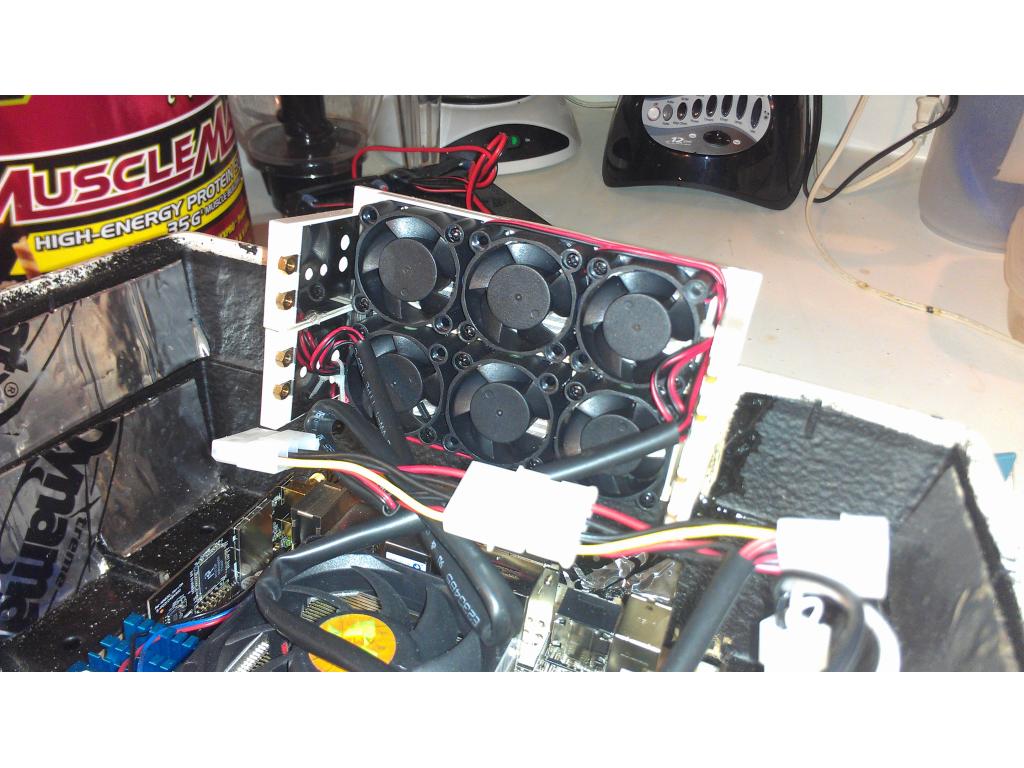
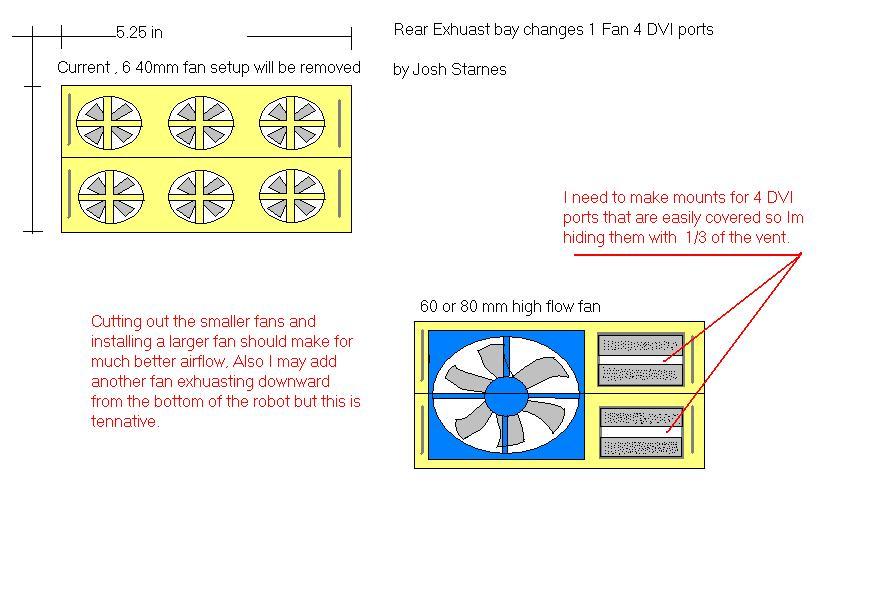
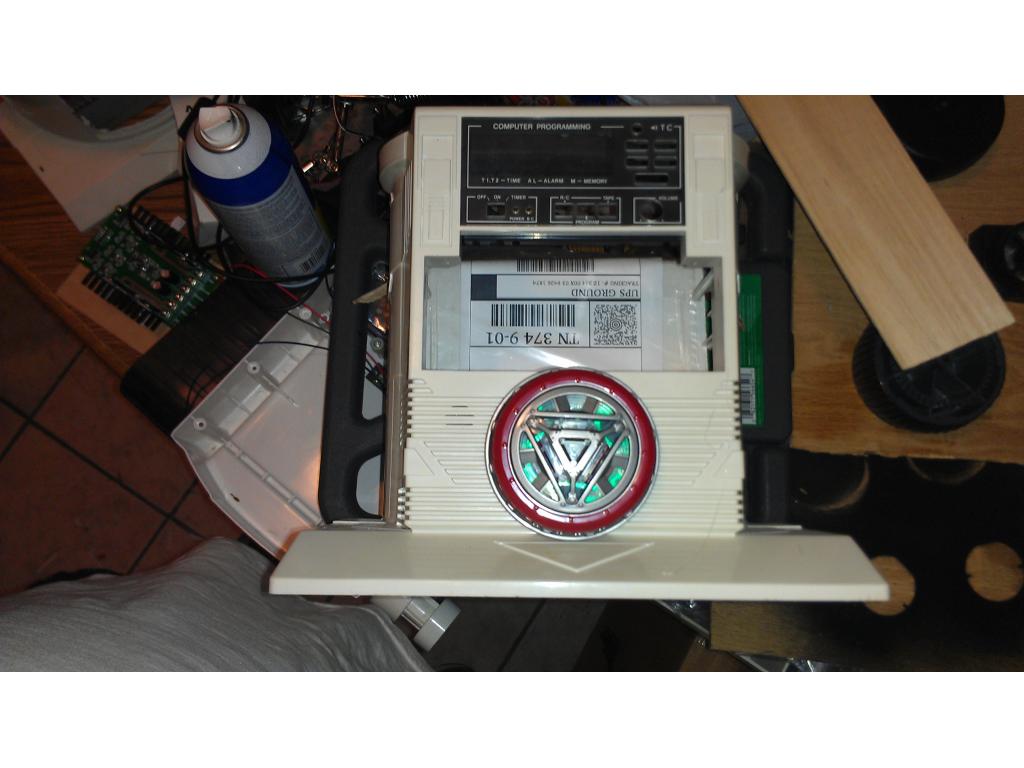
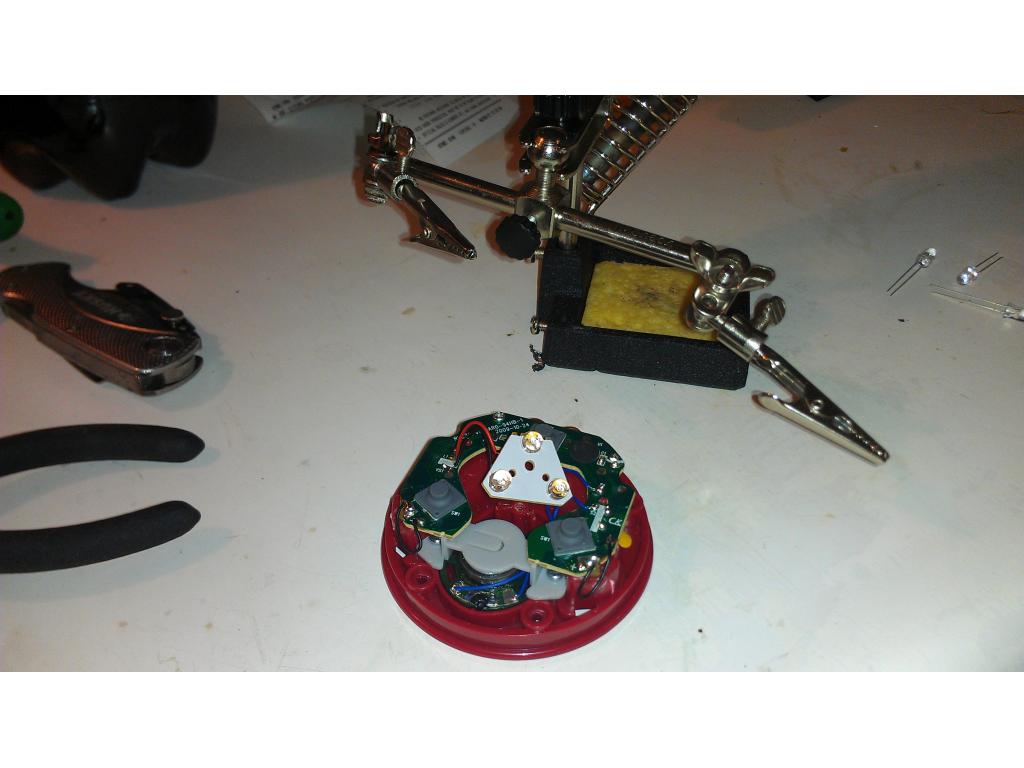
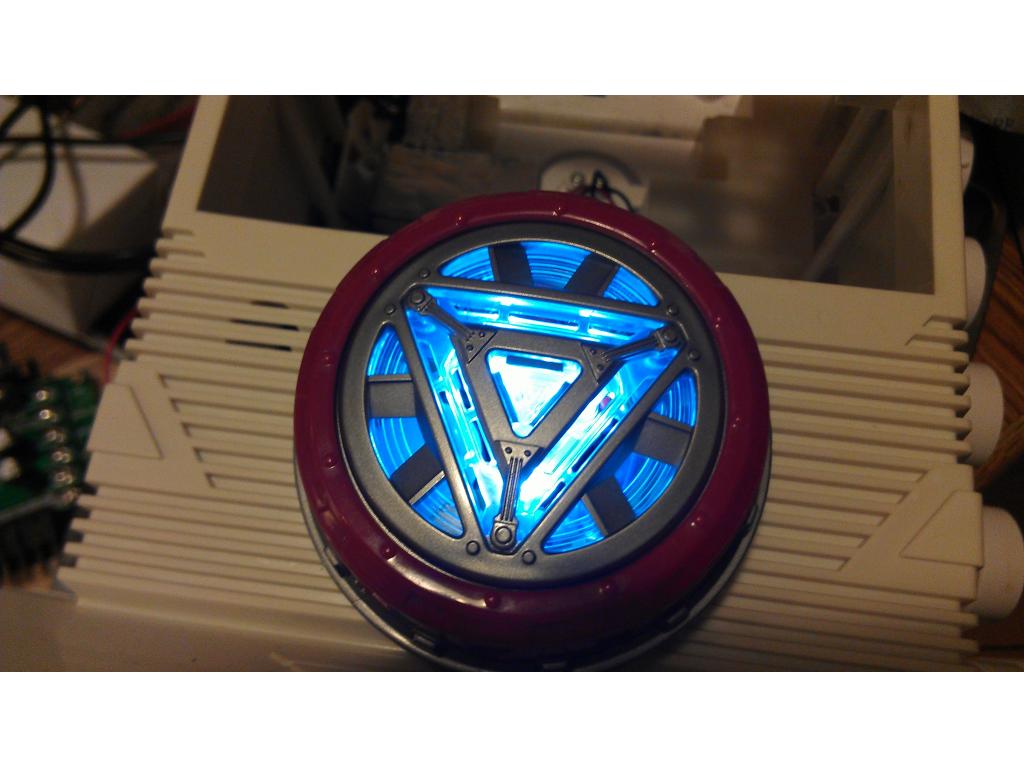
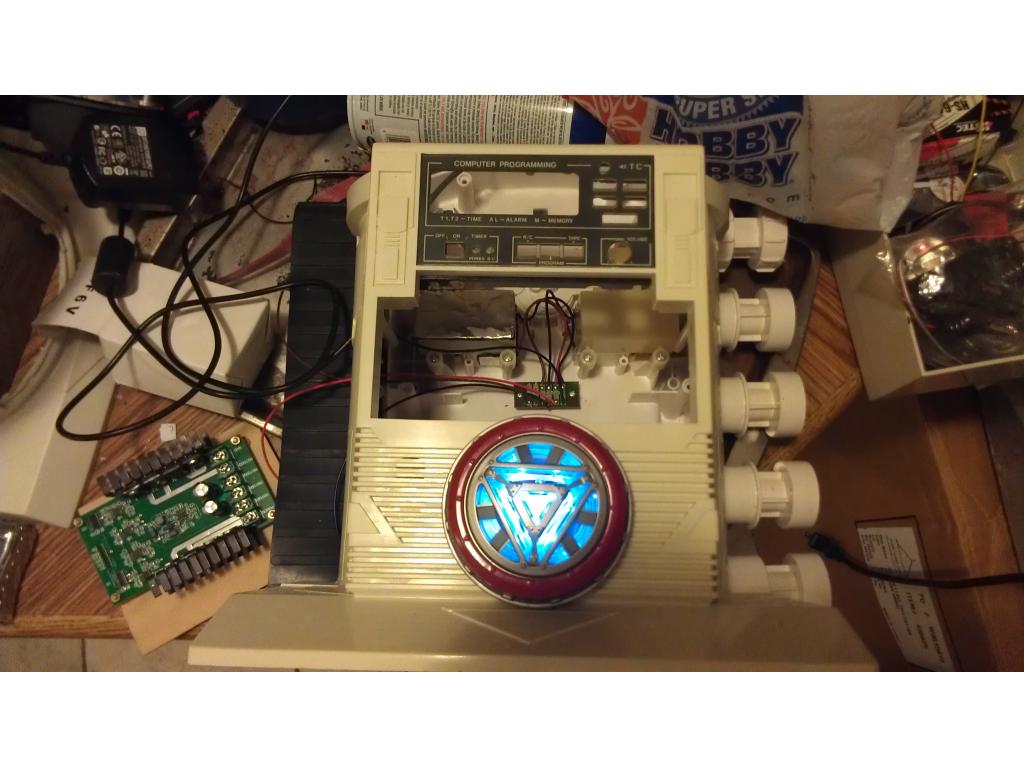
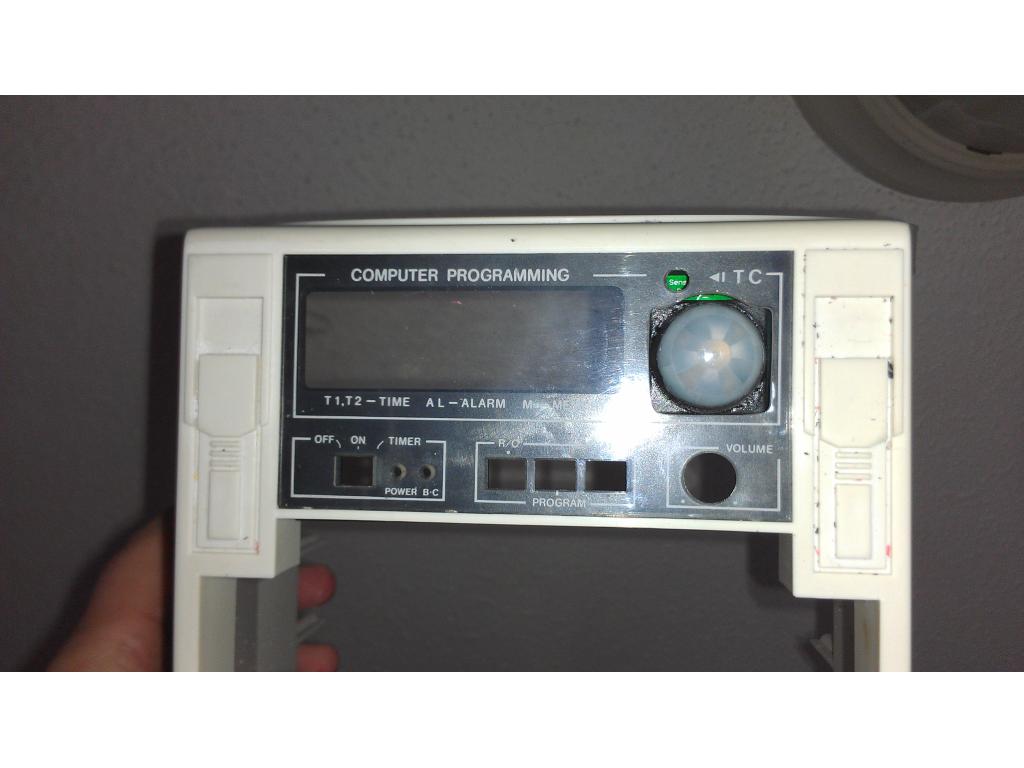
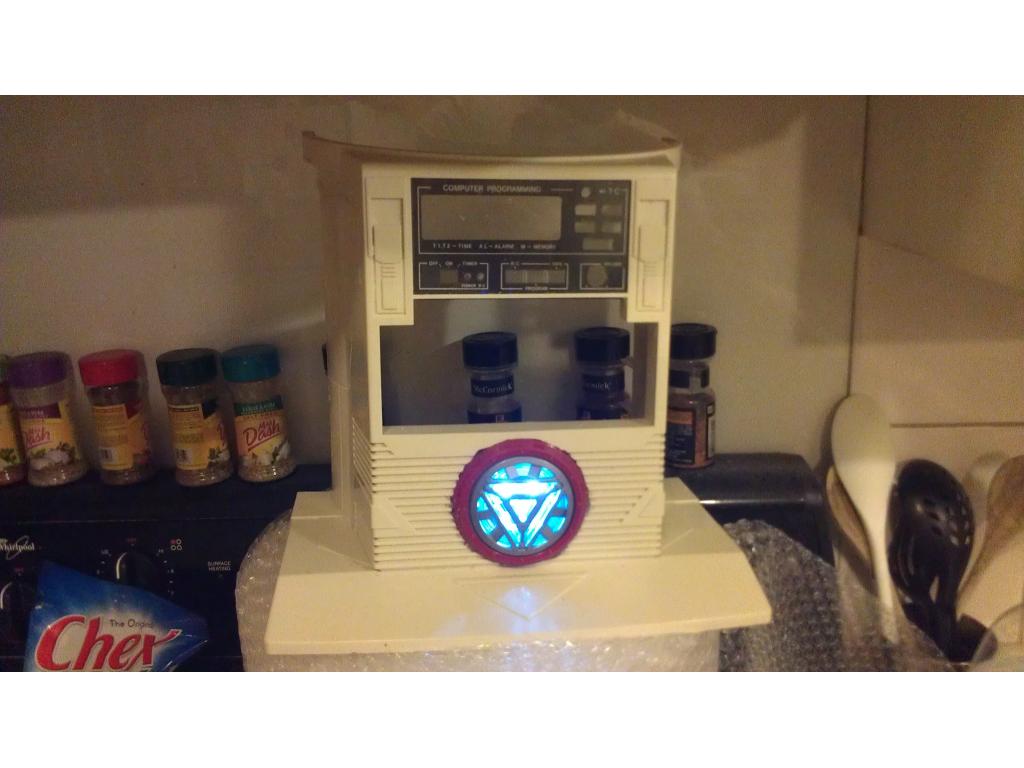
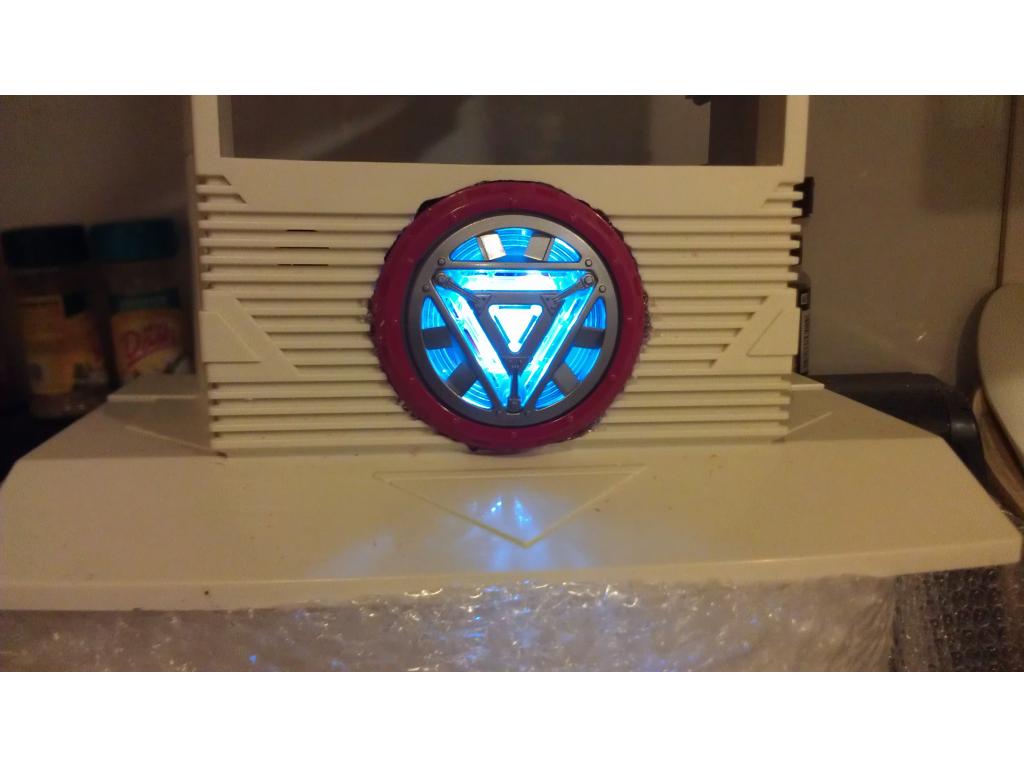
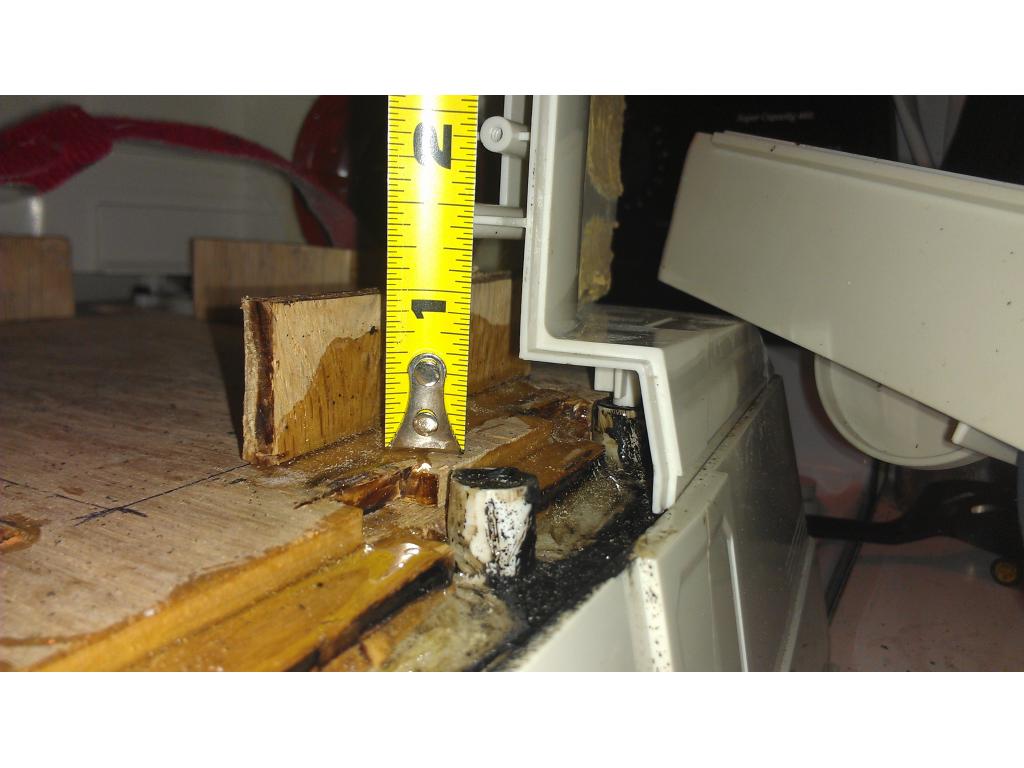
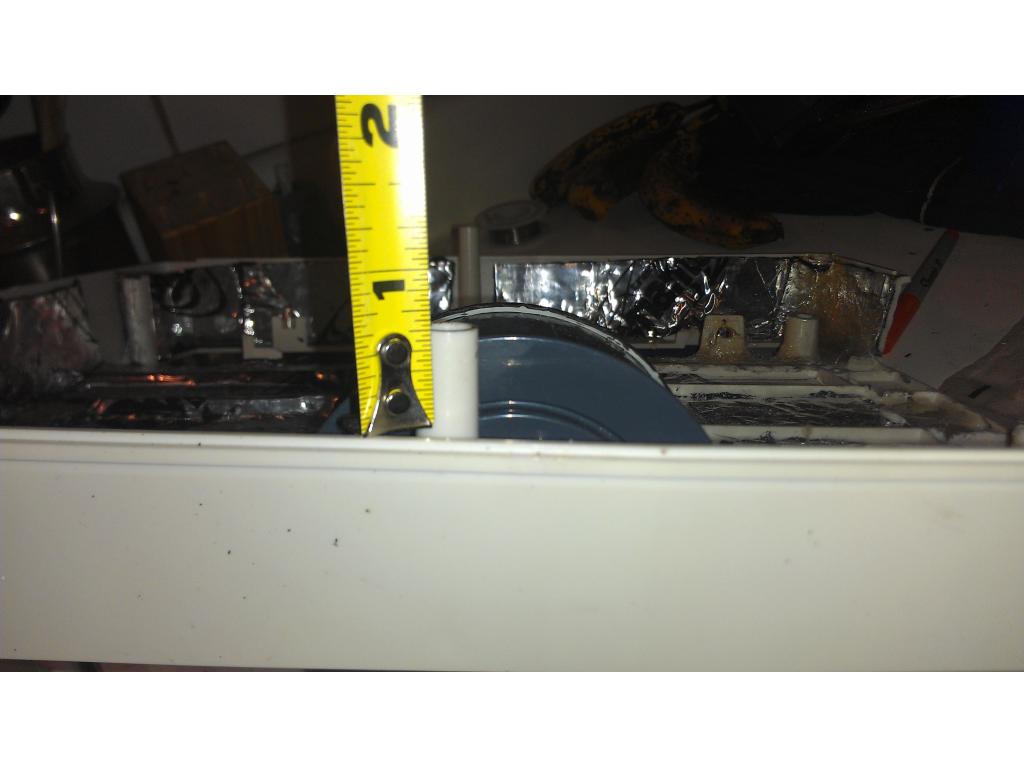
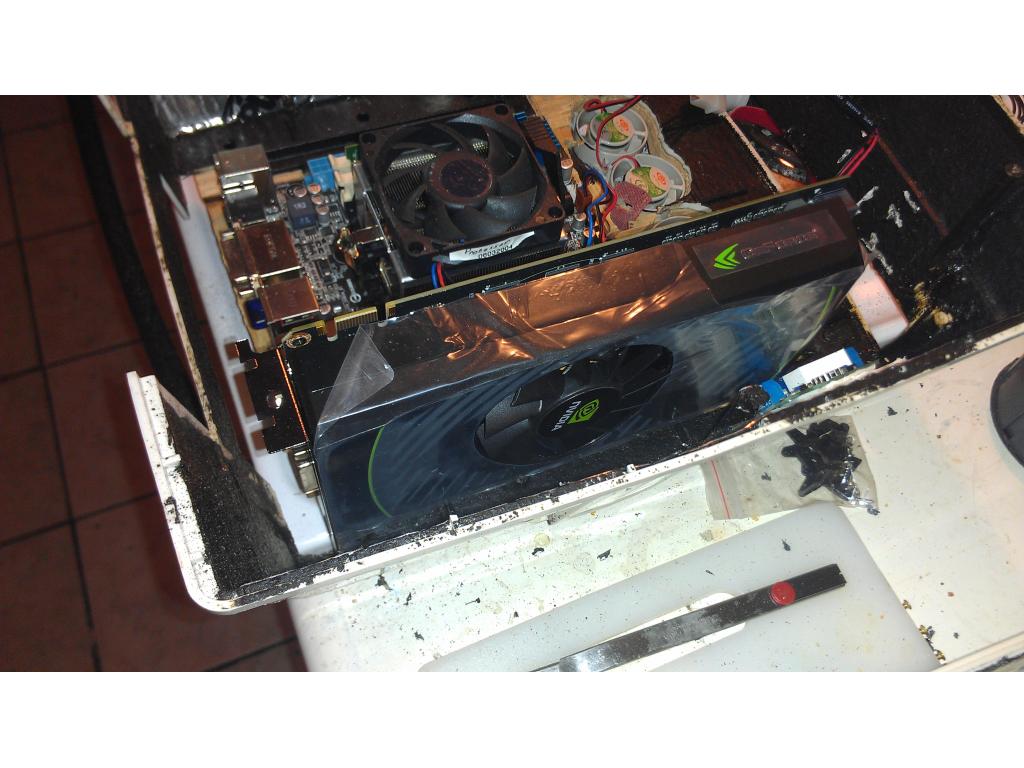
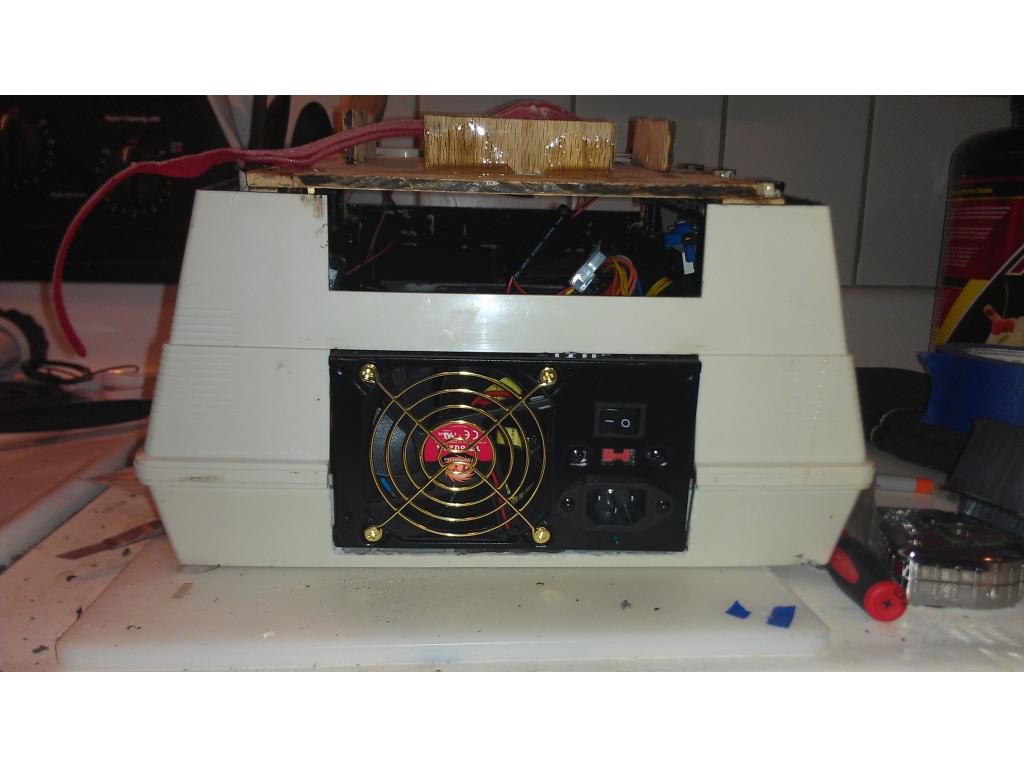
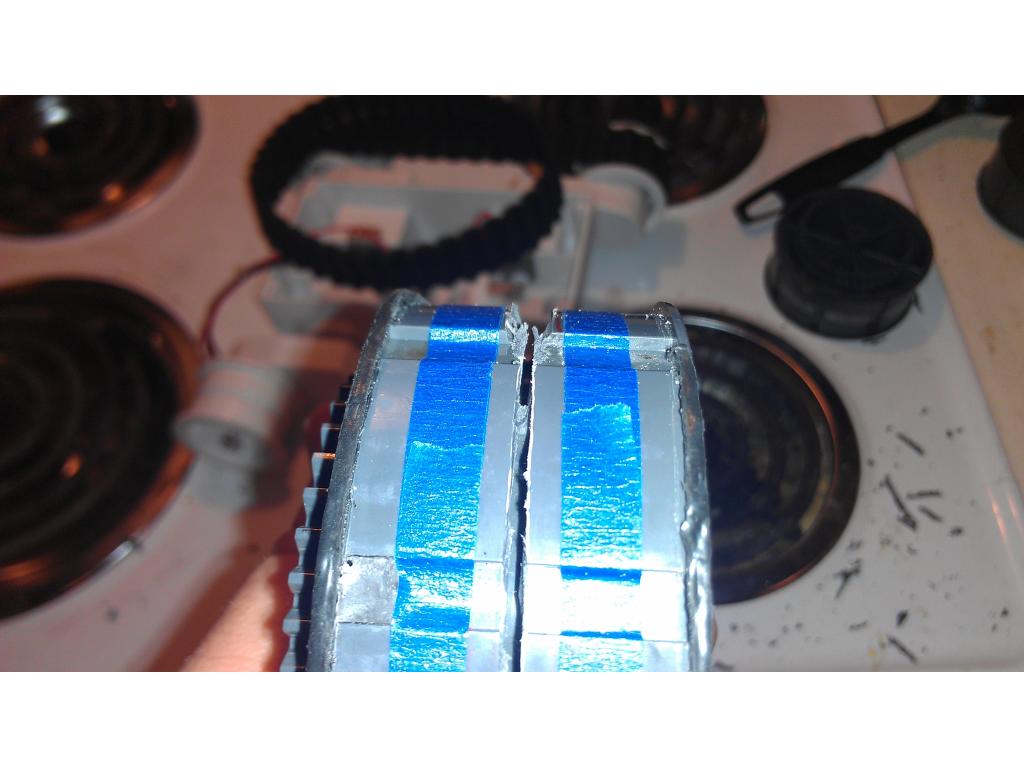
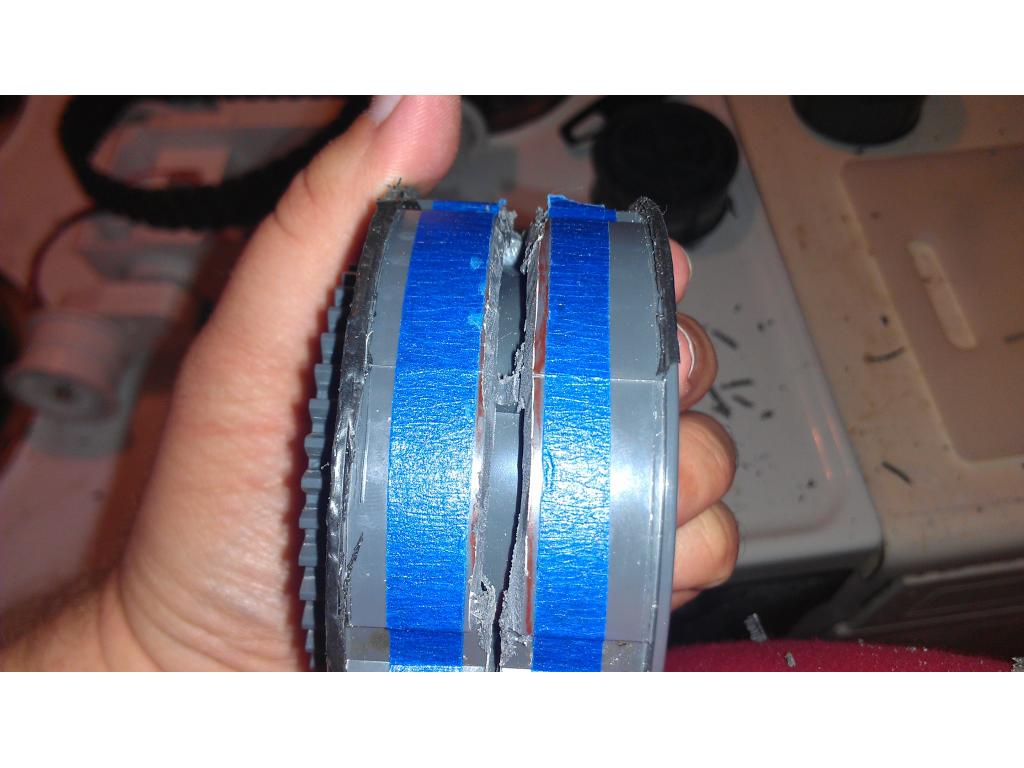
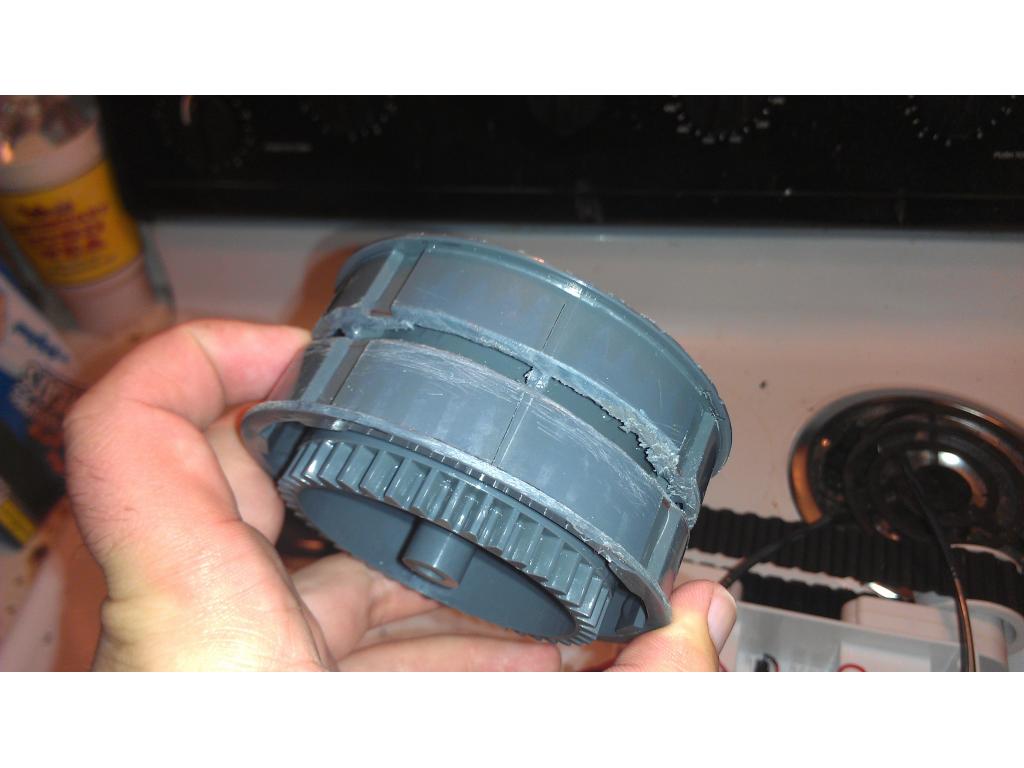
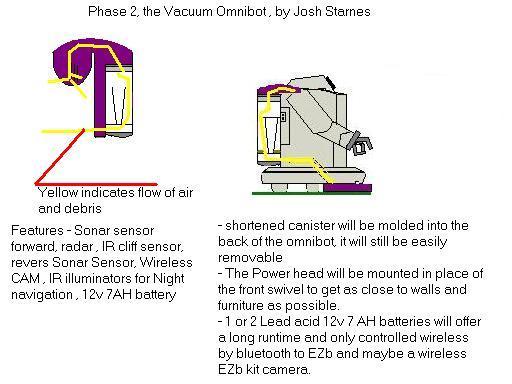
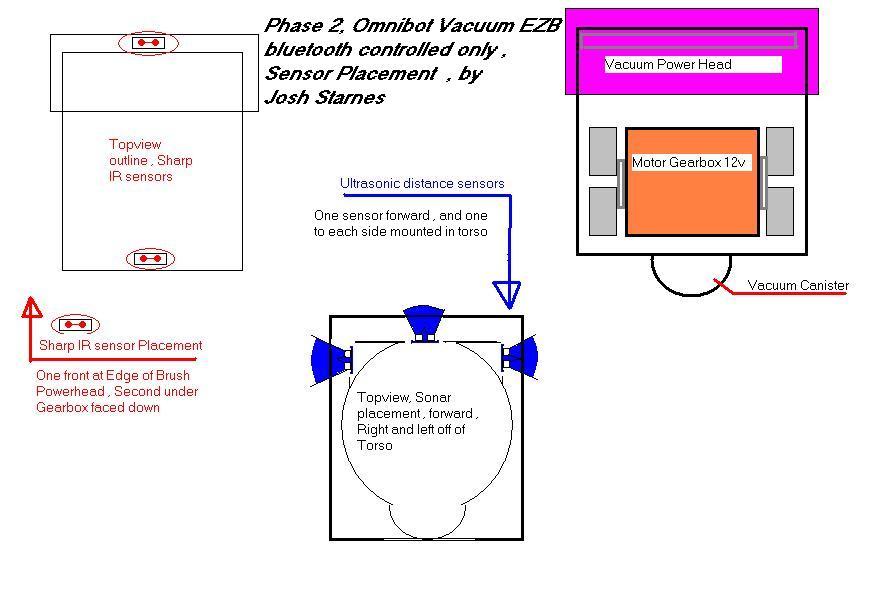
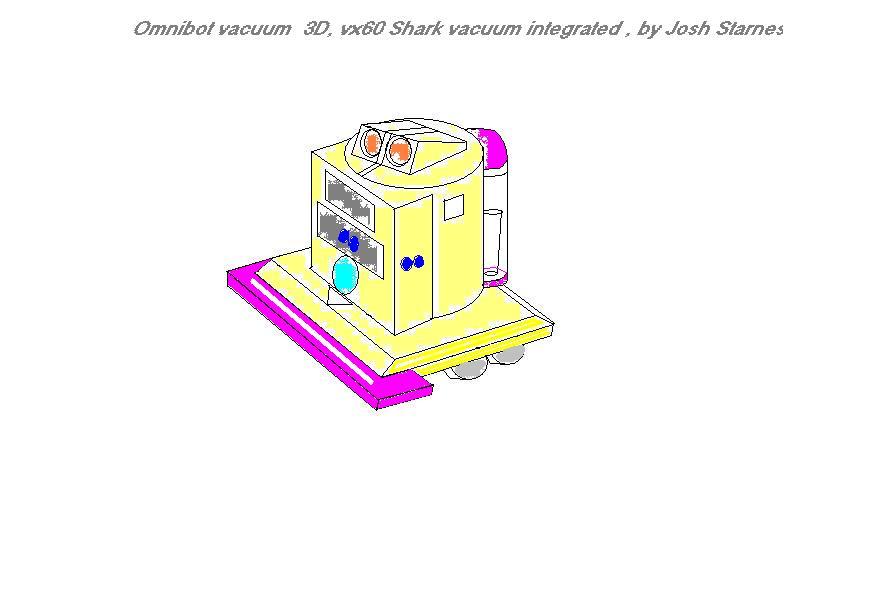
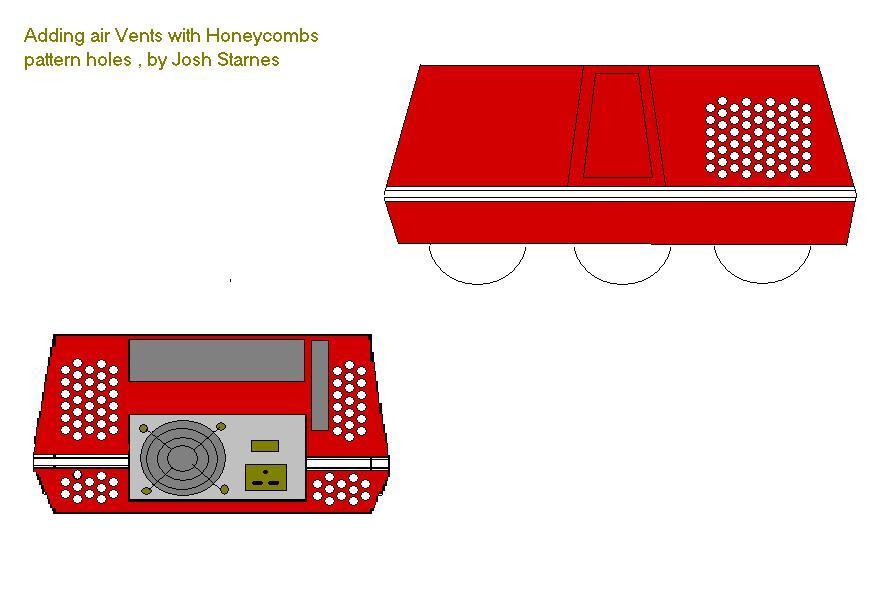
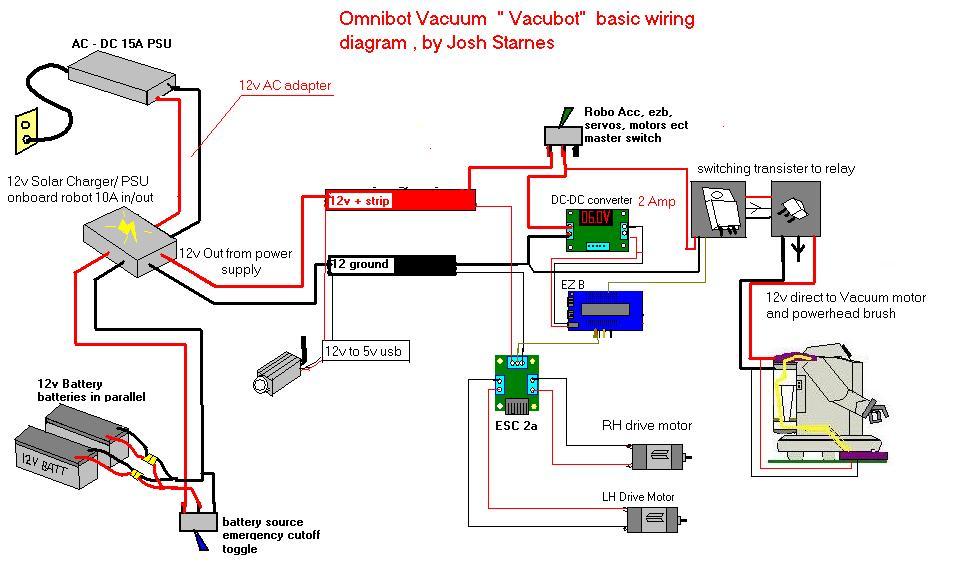
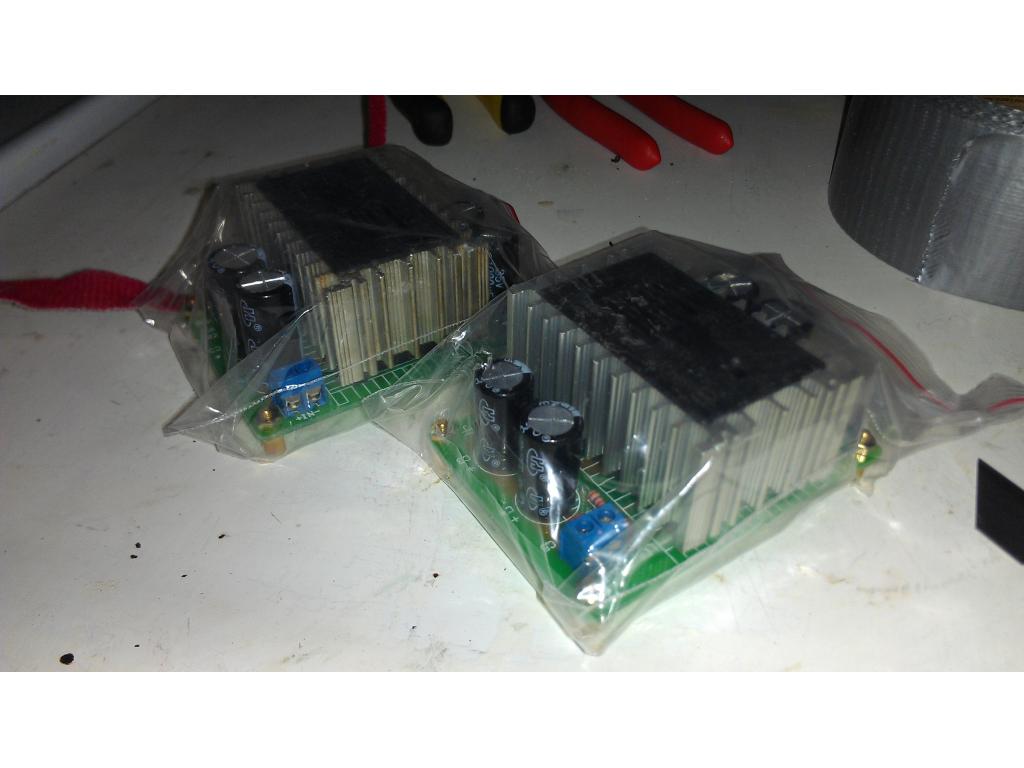
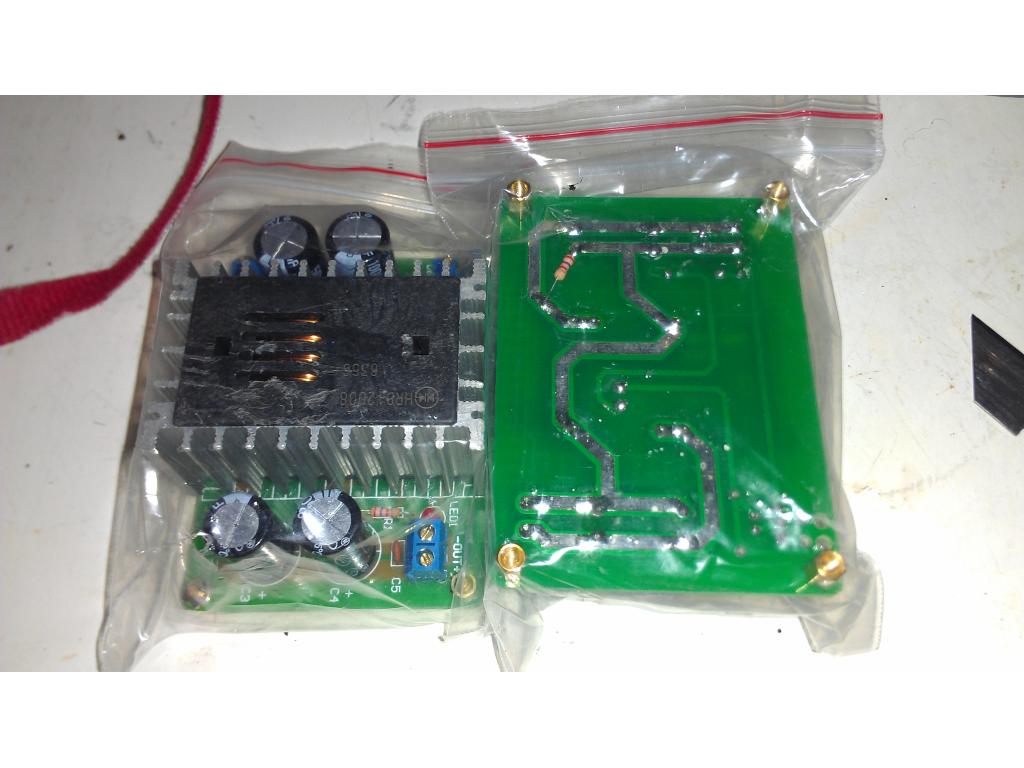
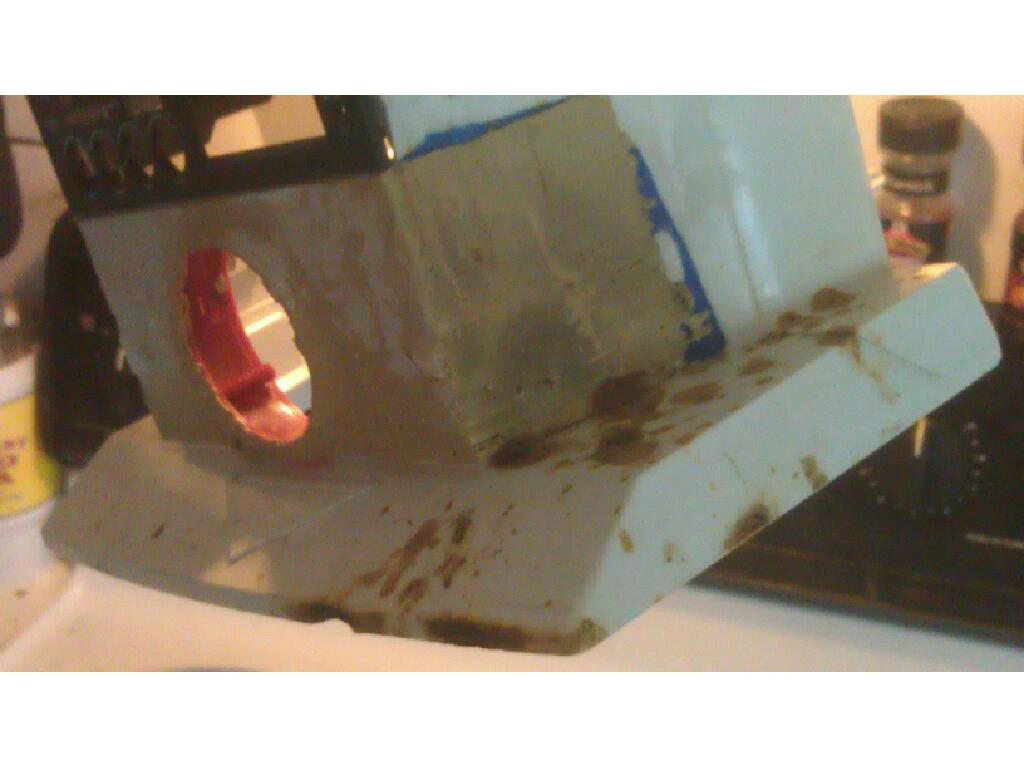
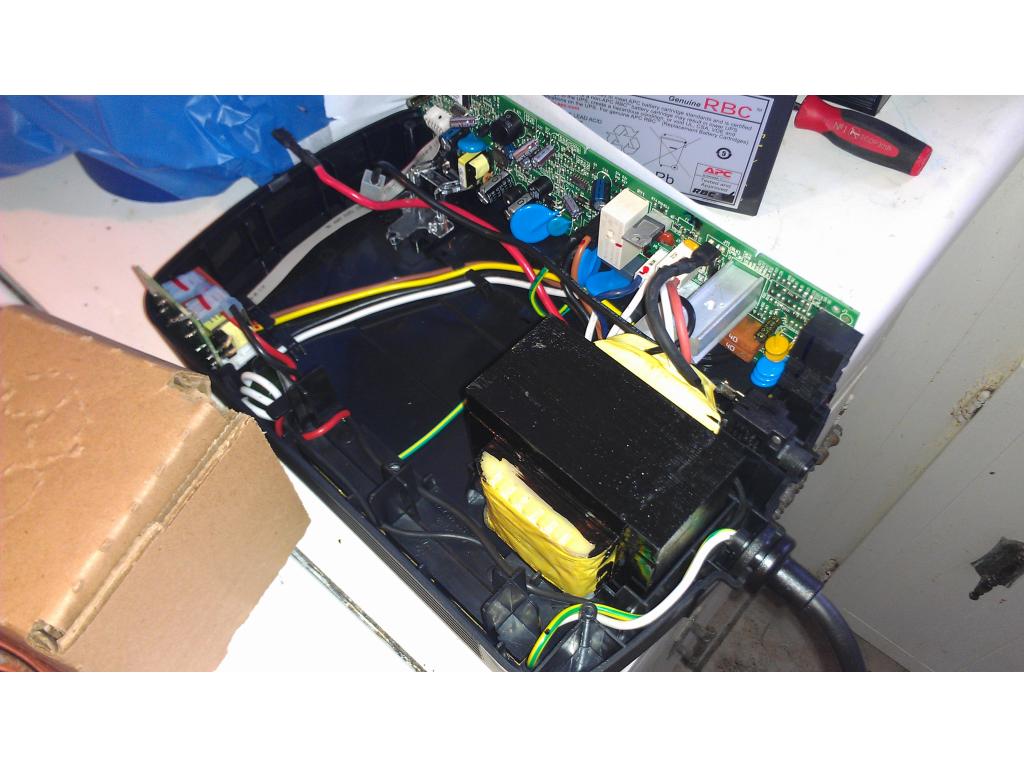
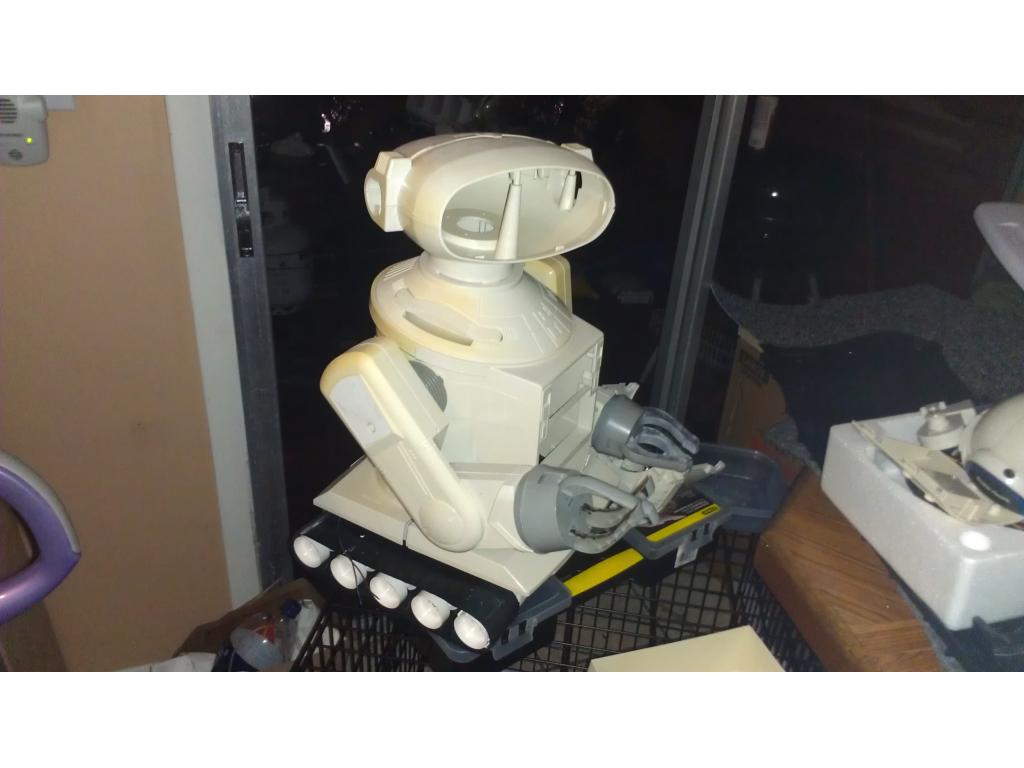
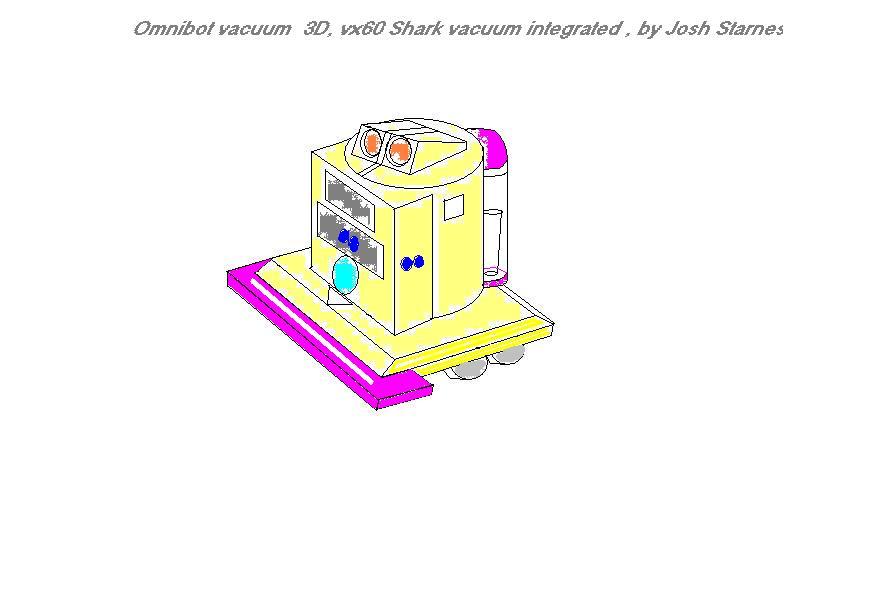
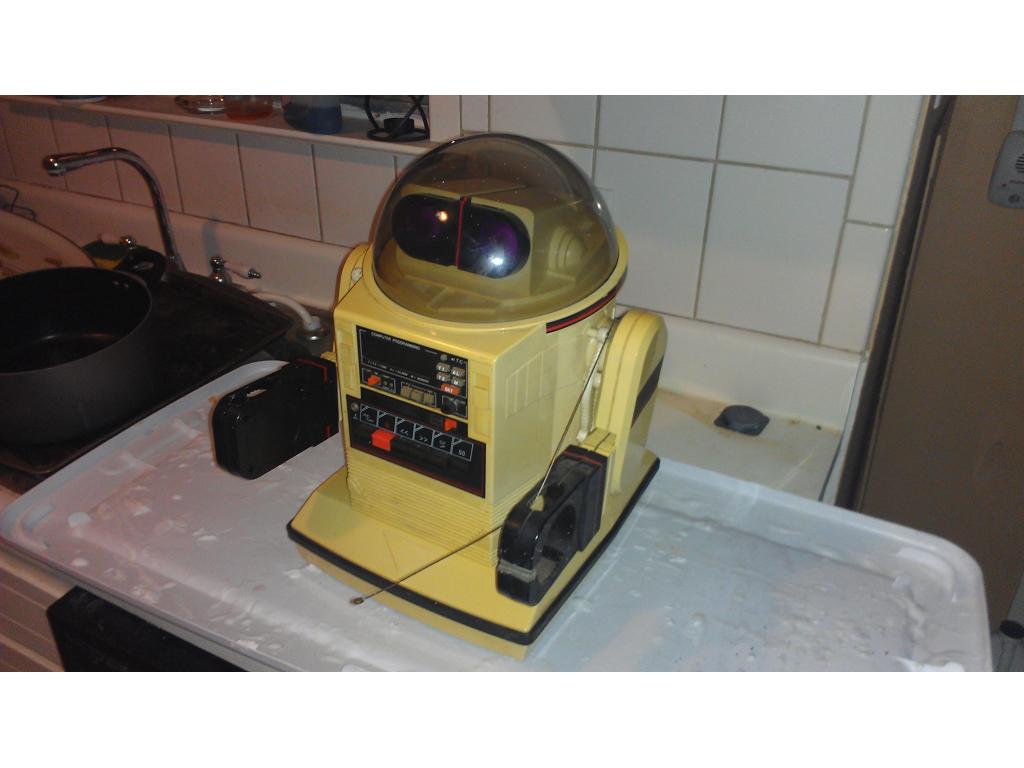
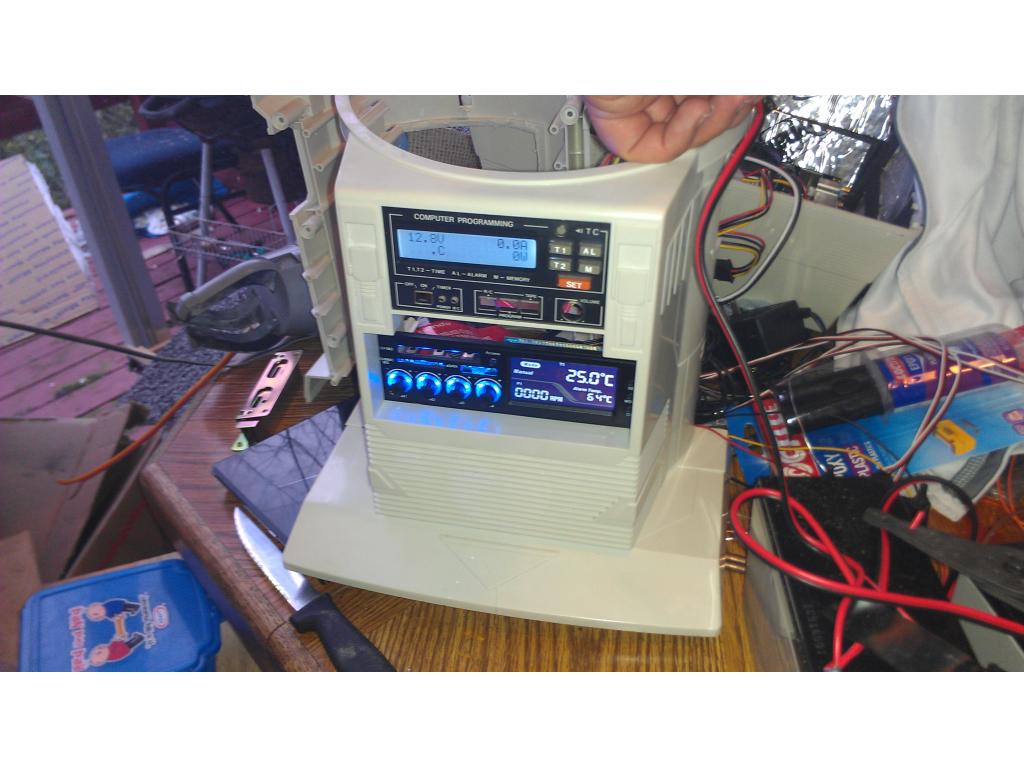
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.
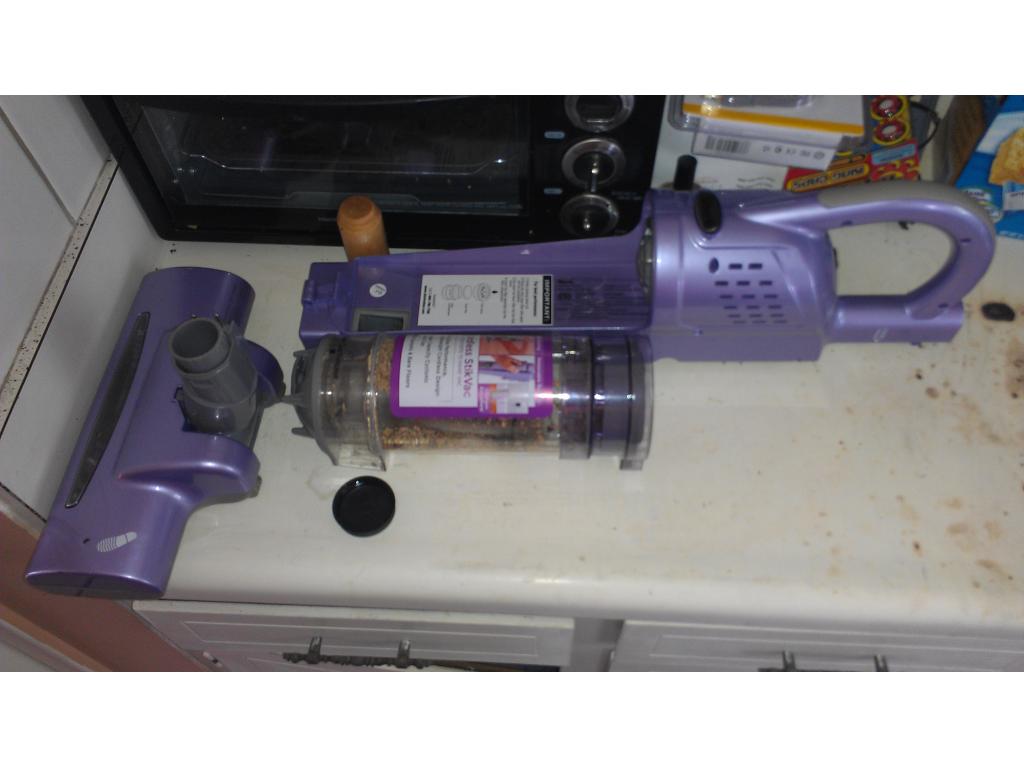
By jstarne1
— Last update
Discover more robots
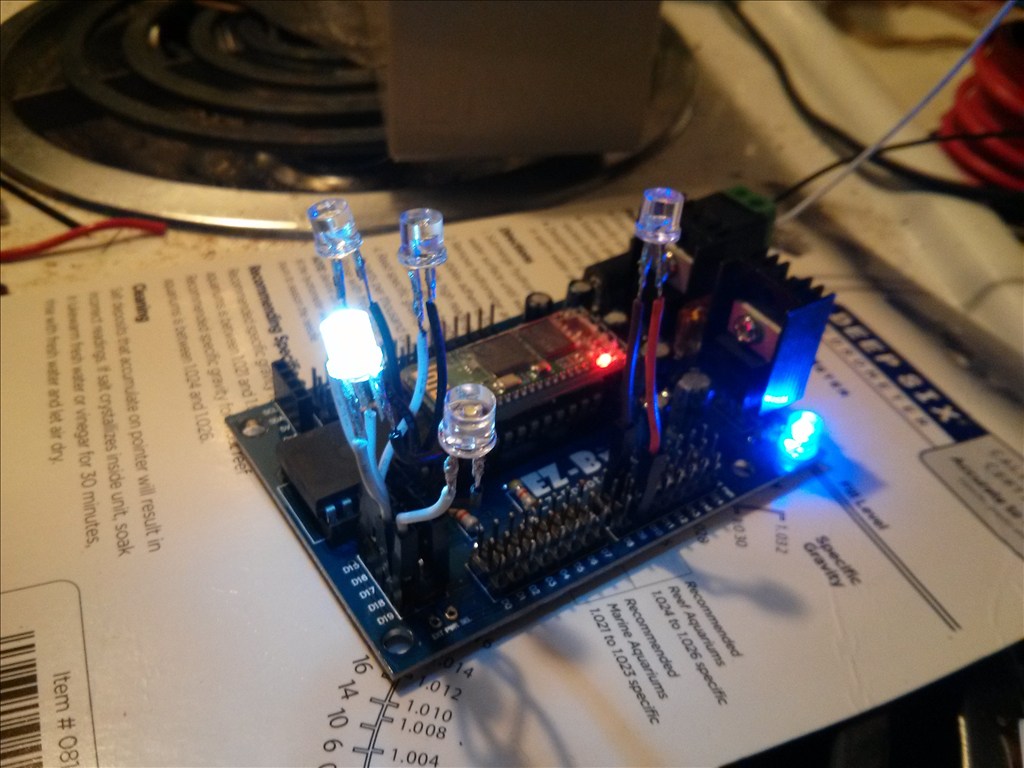
Jstarne1's Easy Led Visual Test For Digital Ports Tutorial J...
Test H-bridge ports using a servo connector: cut the red wire, use white as + and the short lead to ground to watch...
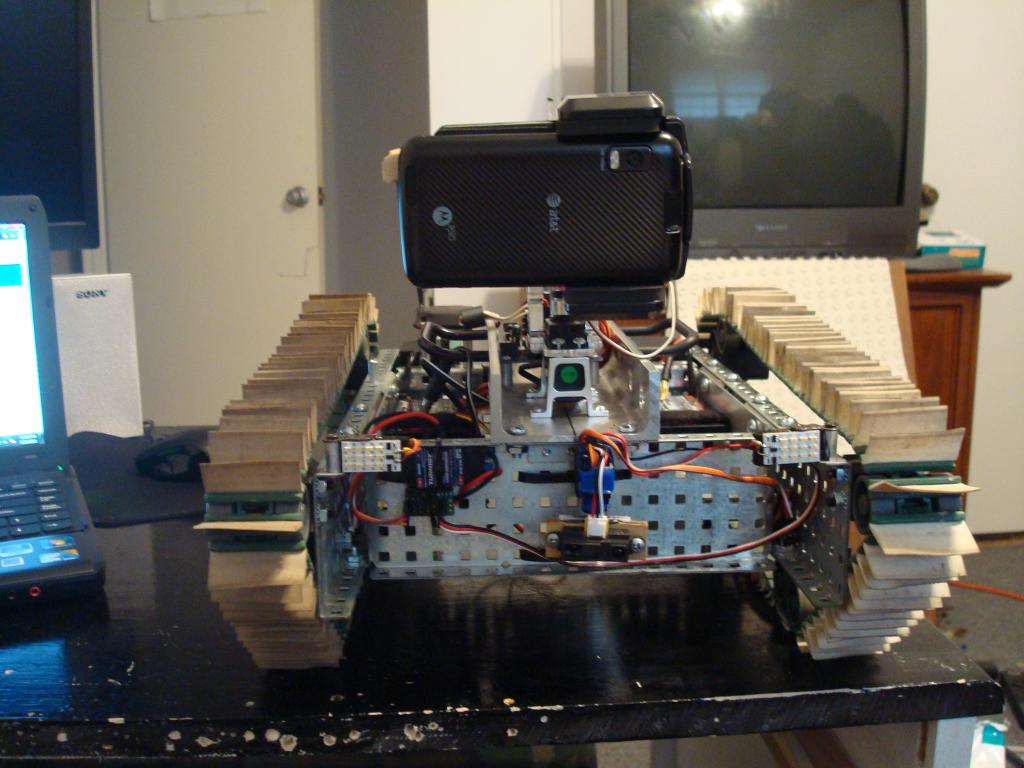
Imrisaac's Ez-B Project V3.0
Surveillance tank with EZ-B and XBee XSC900 for long-range control, Android IP camera streaming video, Vex treads,...
DJ's Philo Junior Color Tracking Test
Control Philo Junior with Synthiam ARC camera 'Track By Relative Position' and WiiMote for simple, cost-effective,...

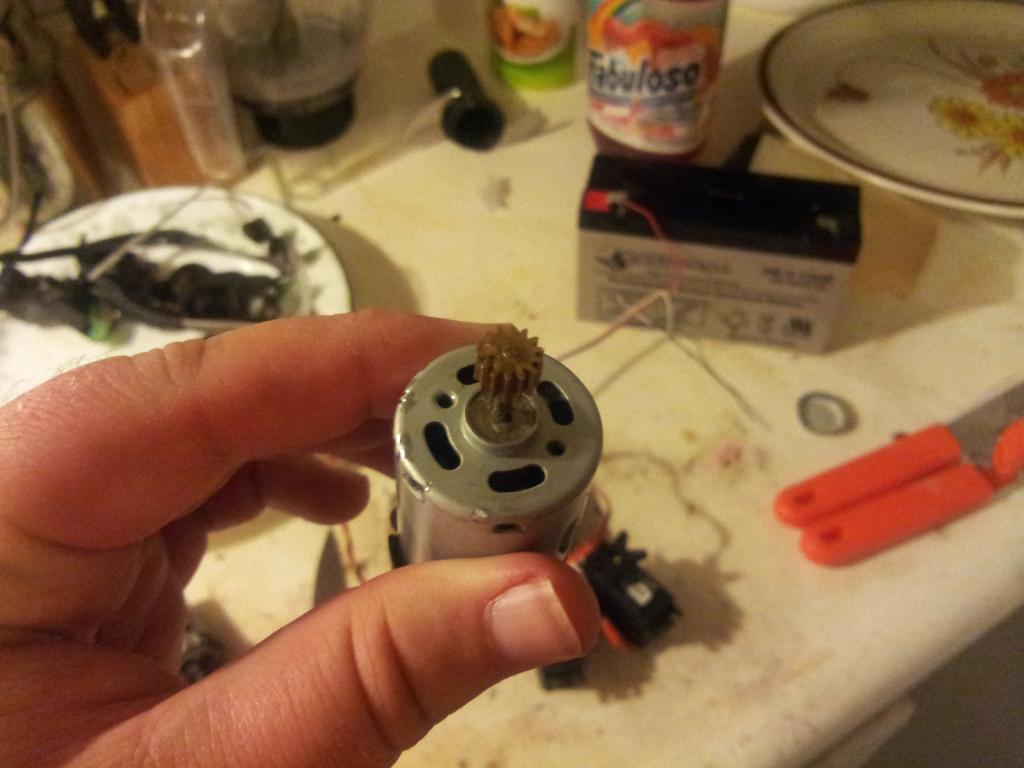
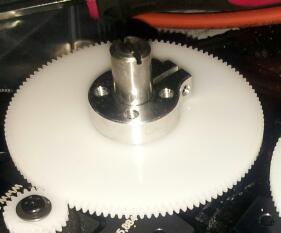
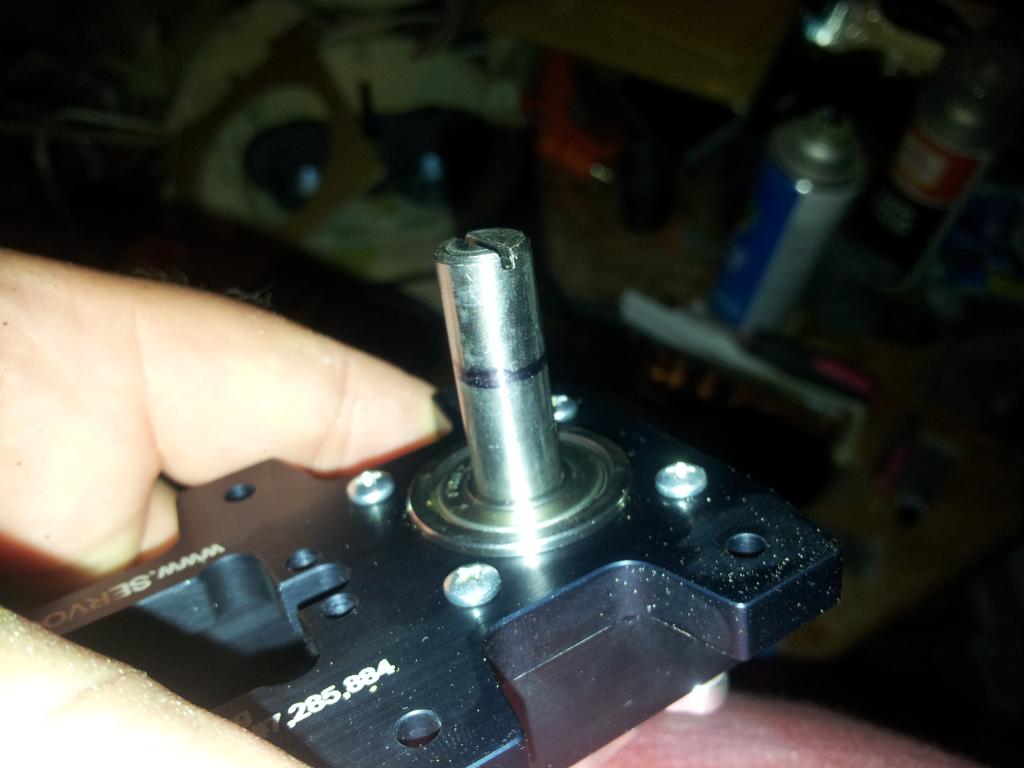
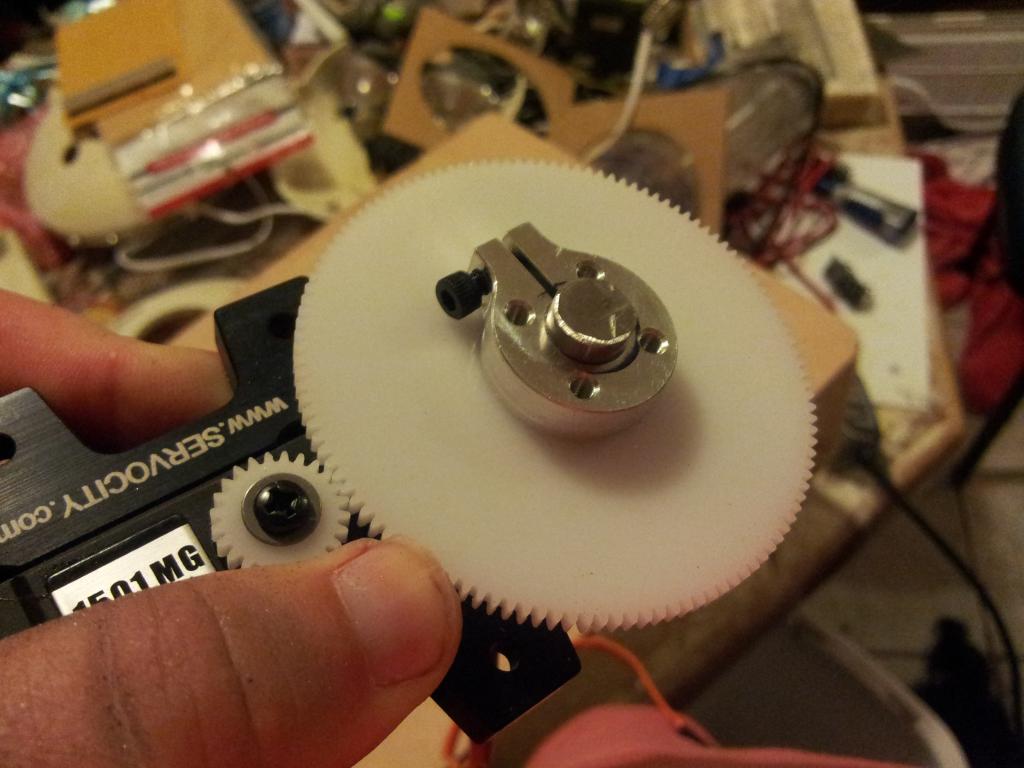
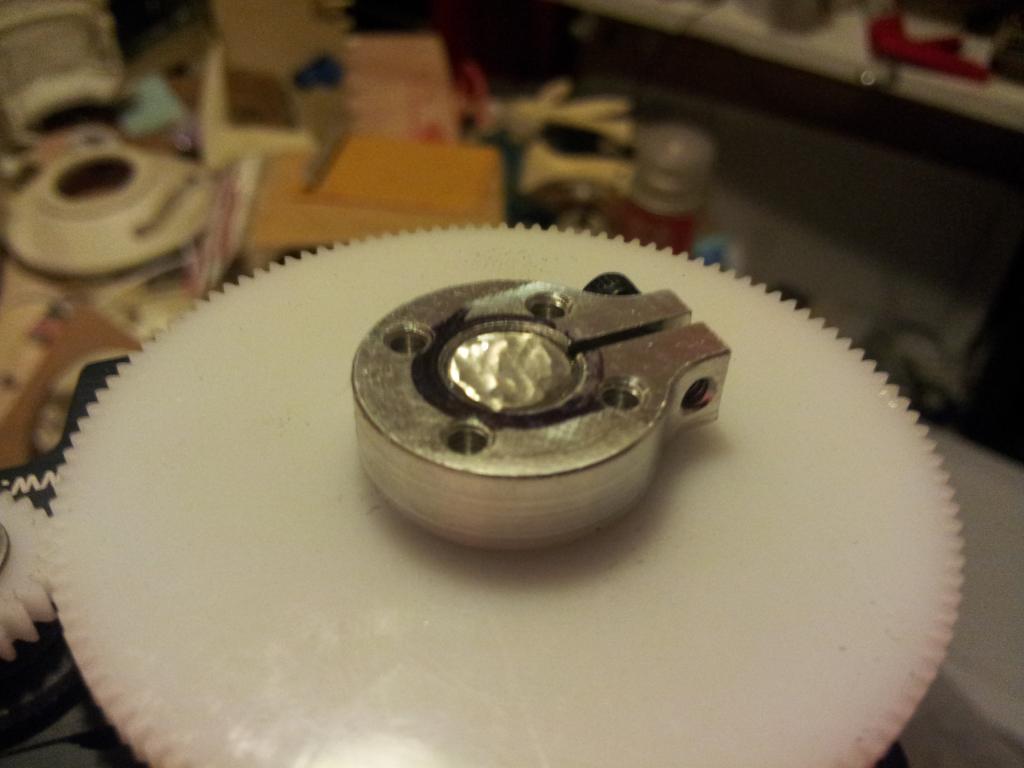
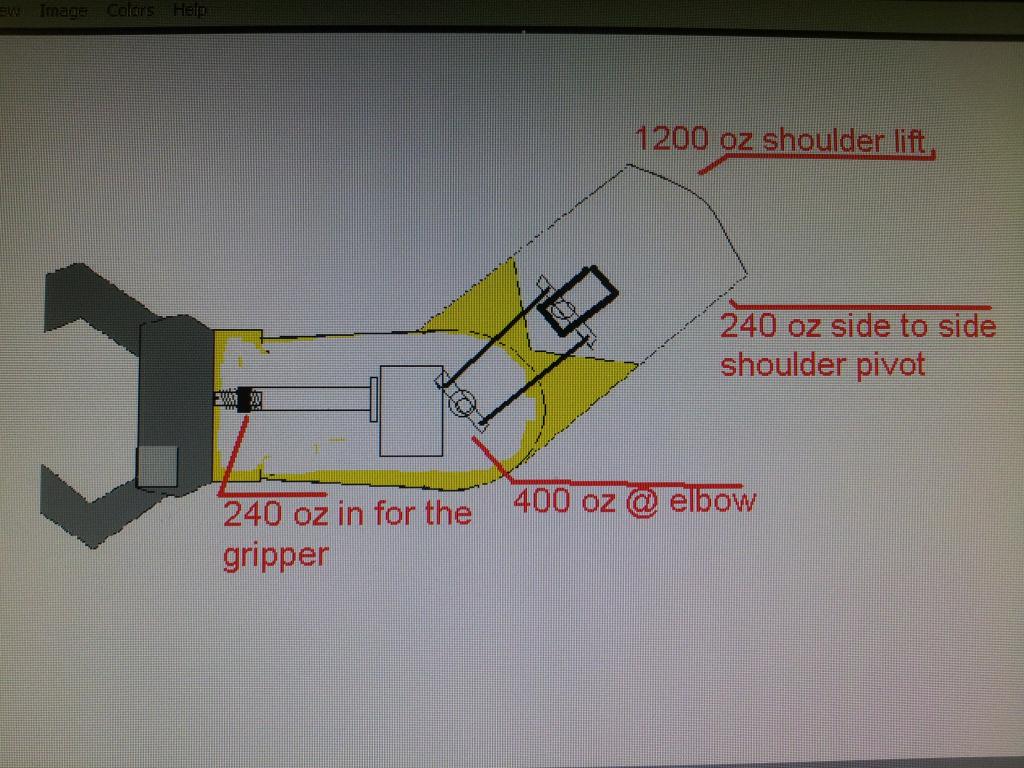
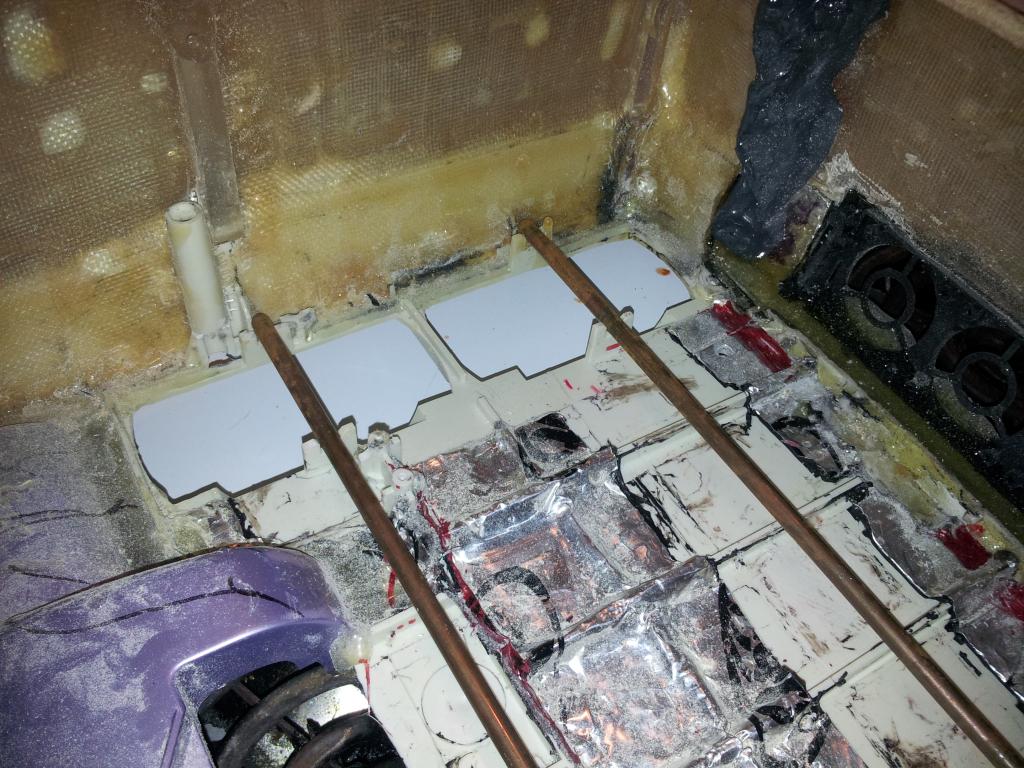
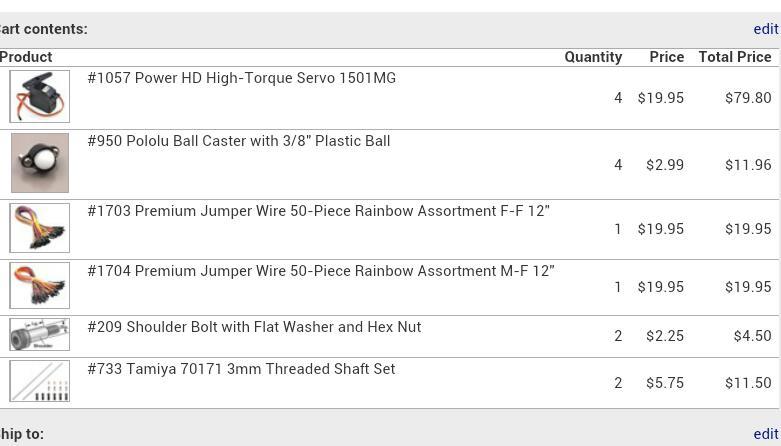
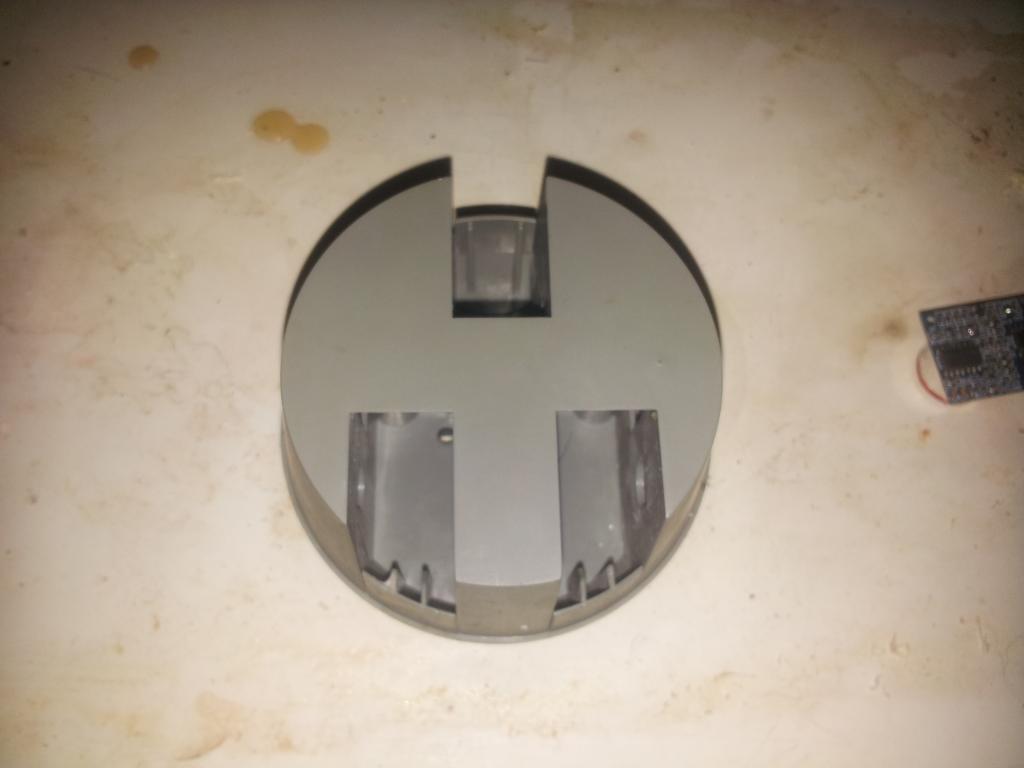
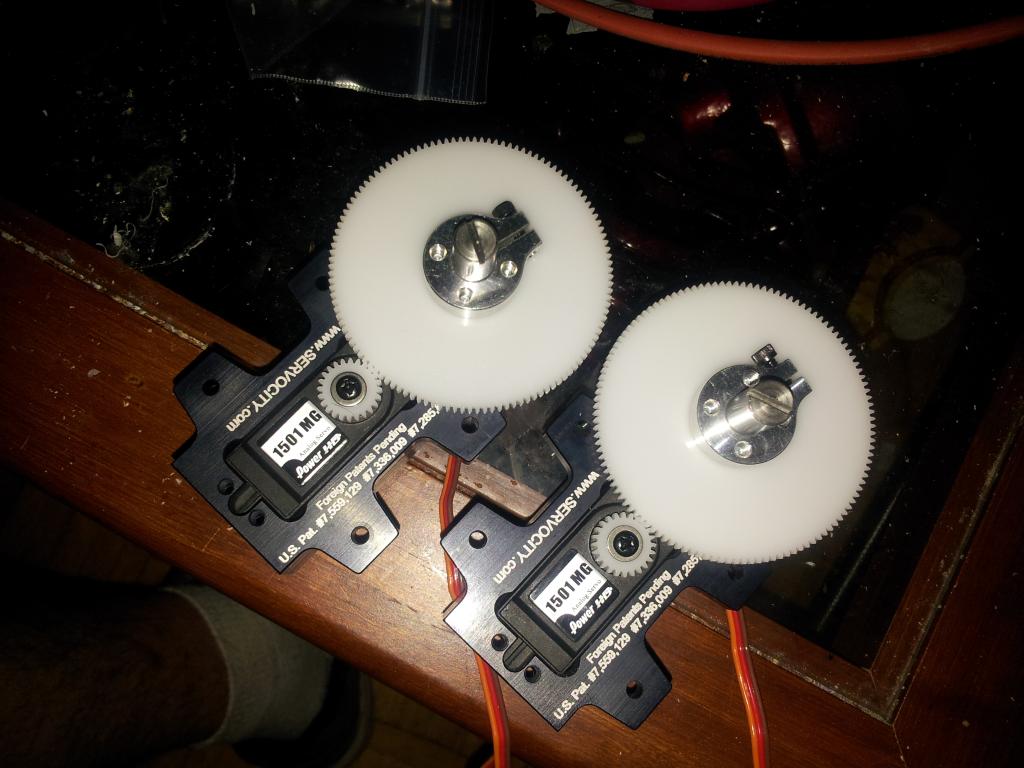
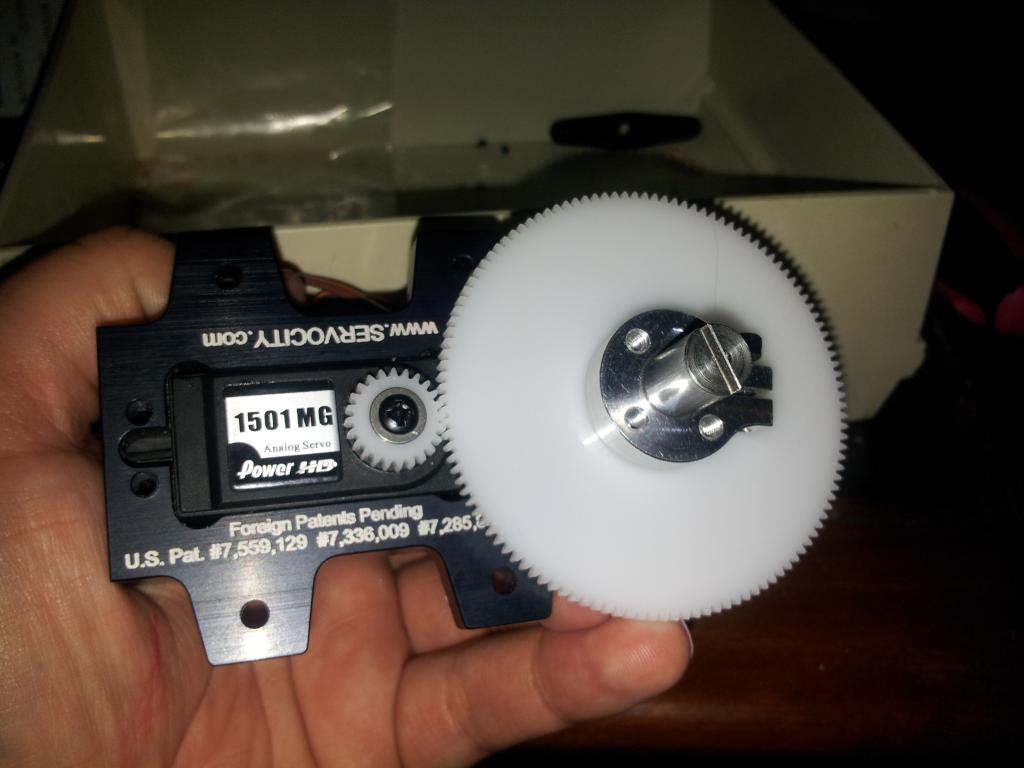
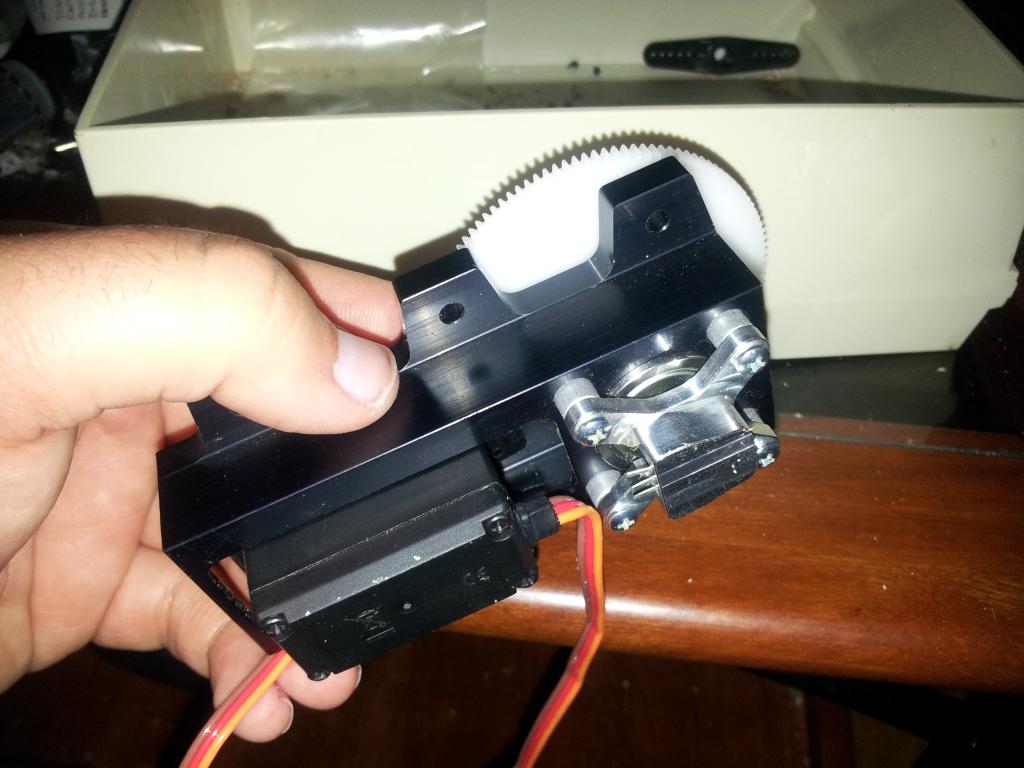
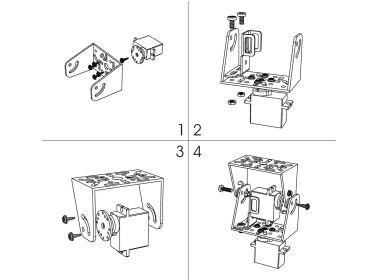
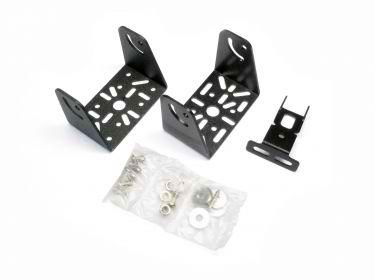
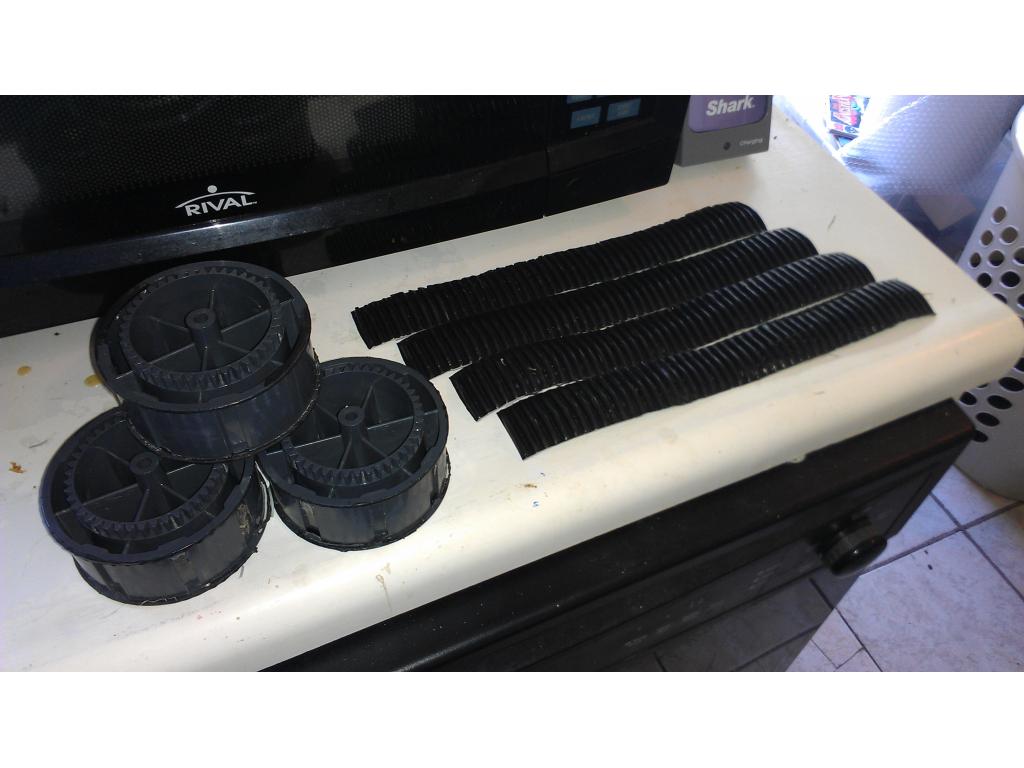
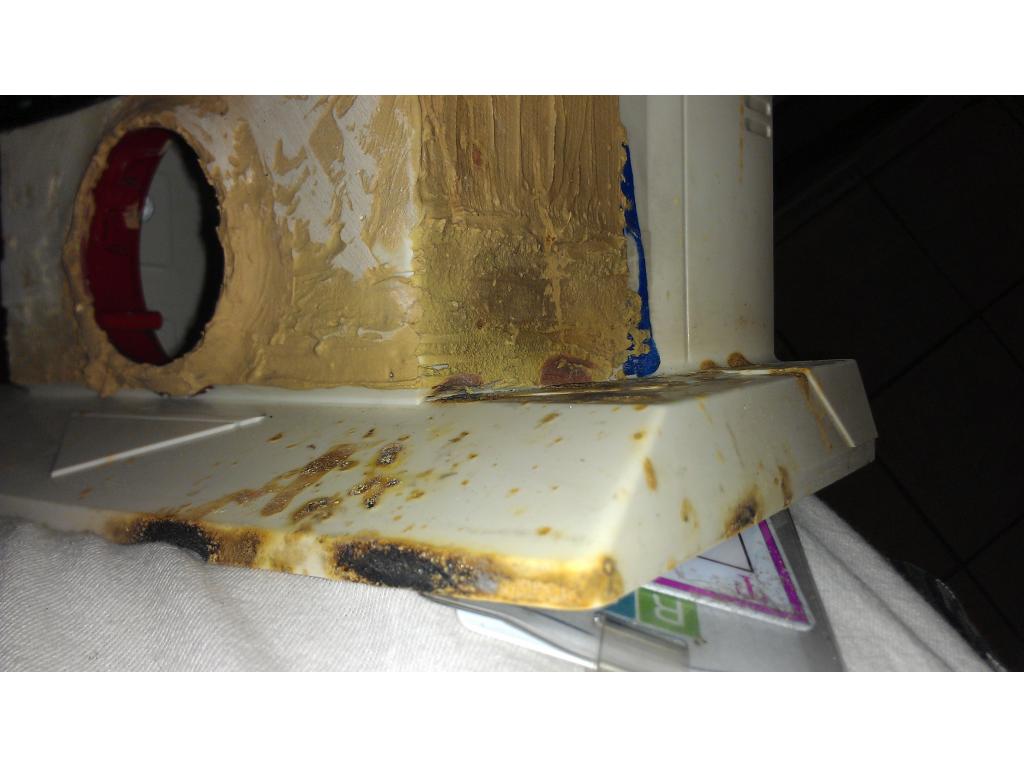
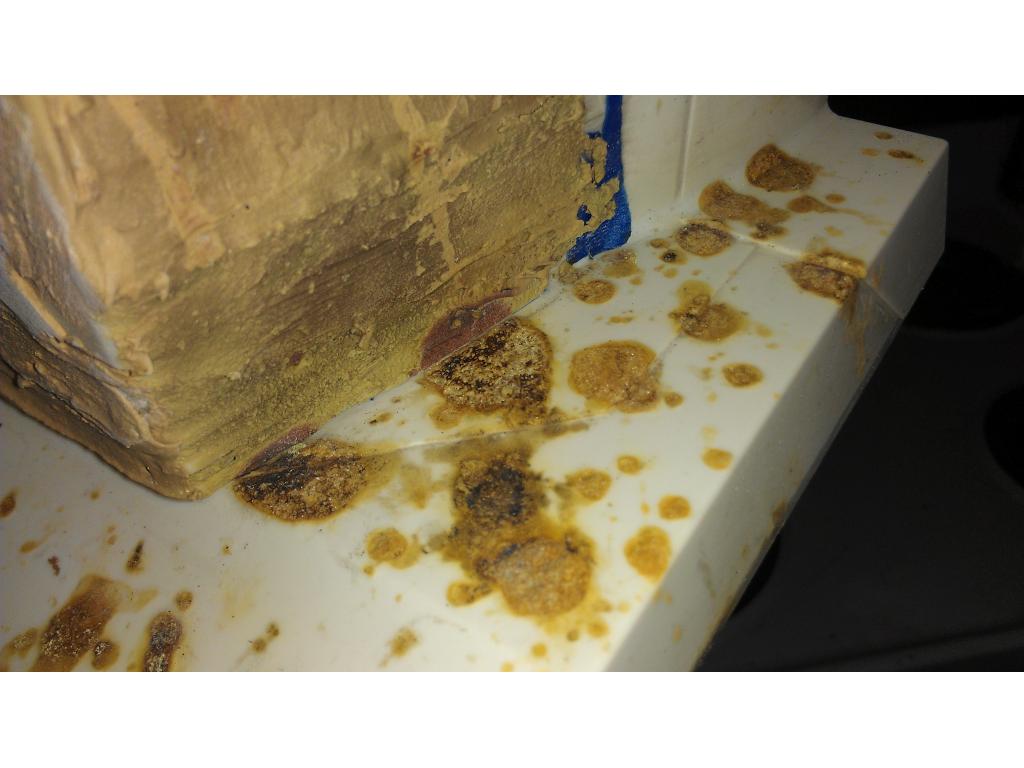
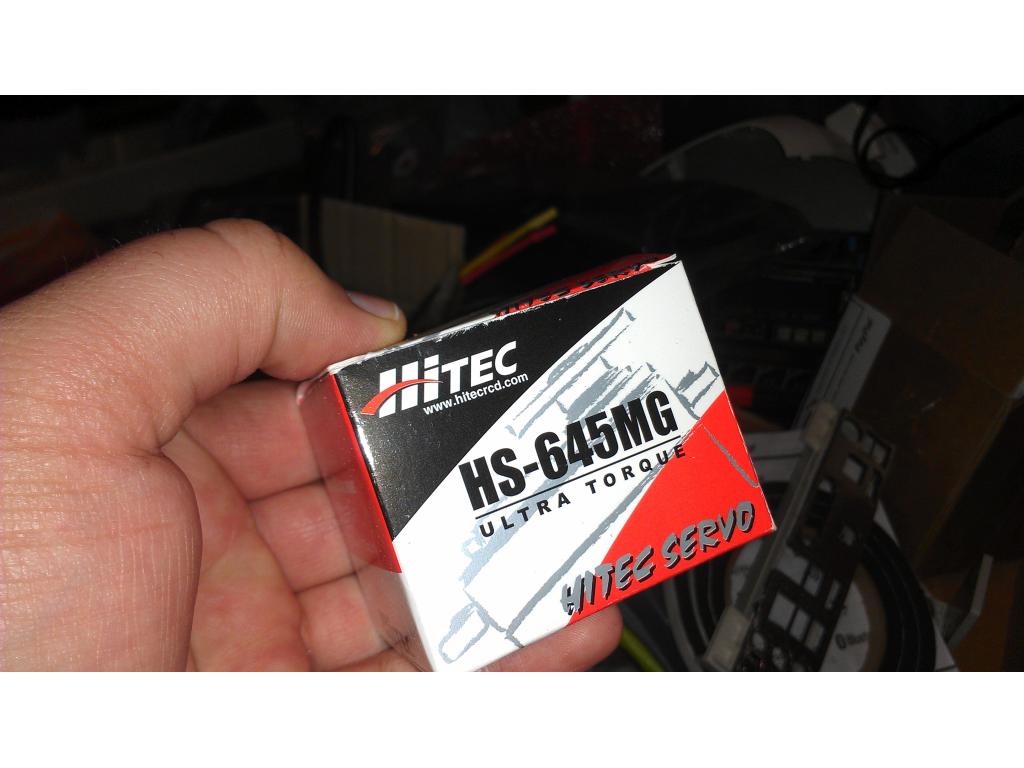
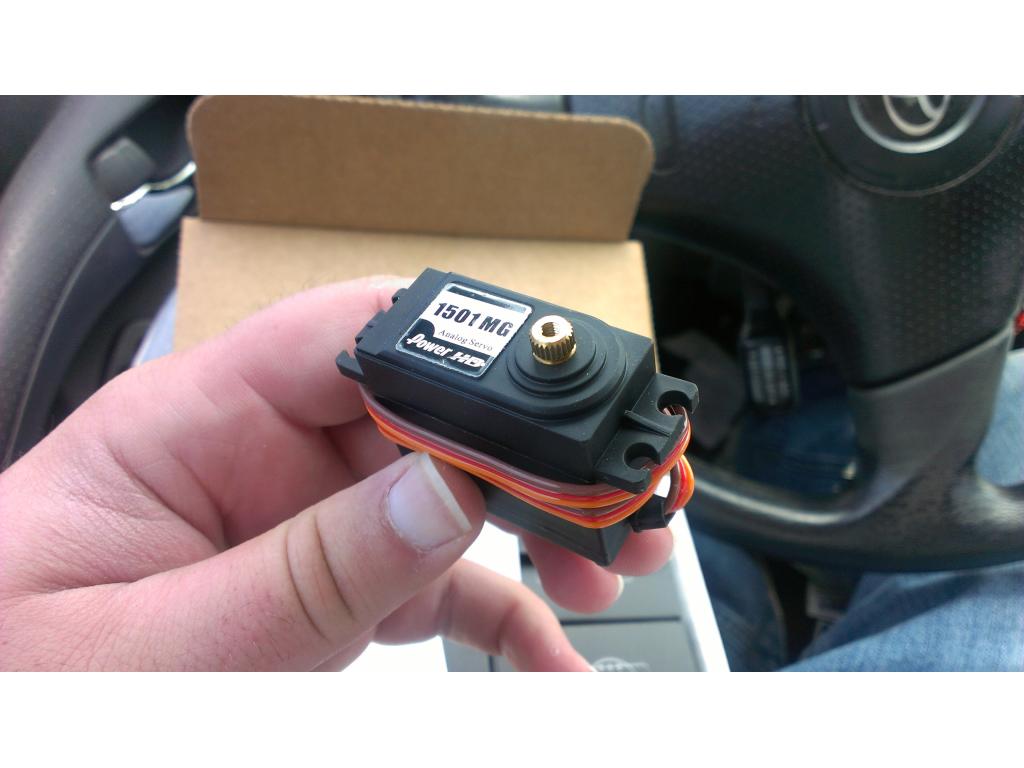
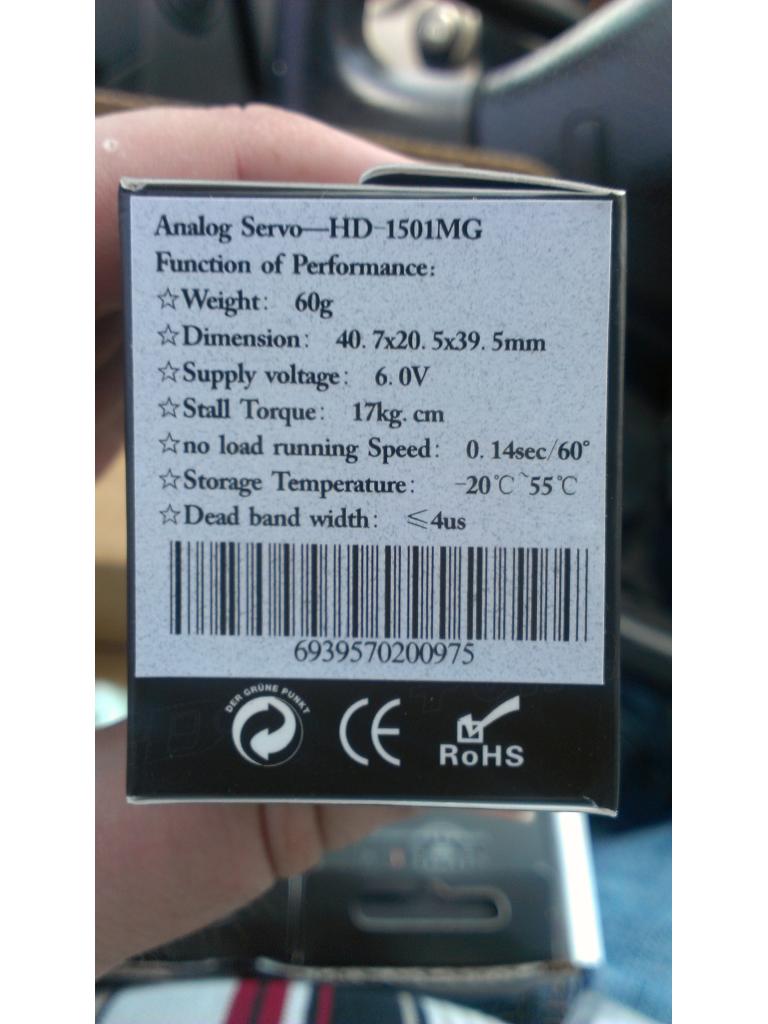
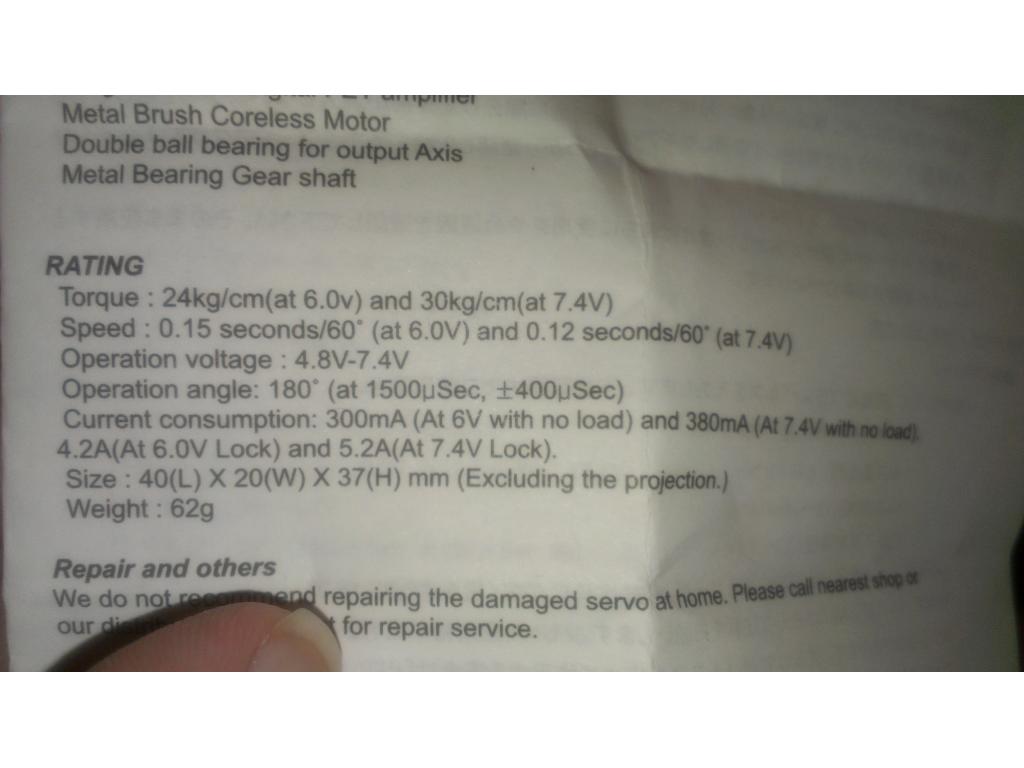
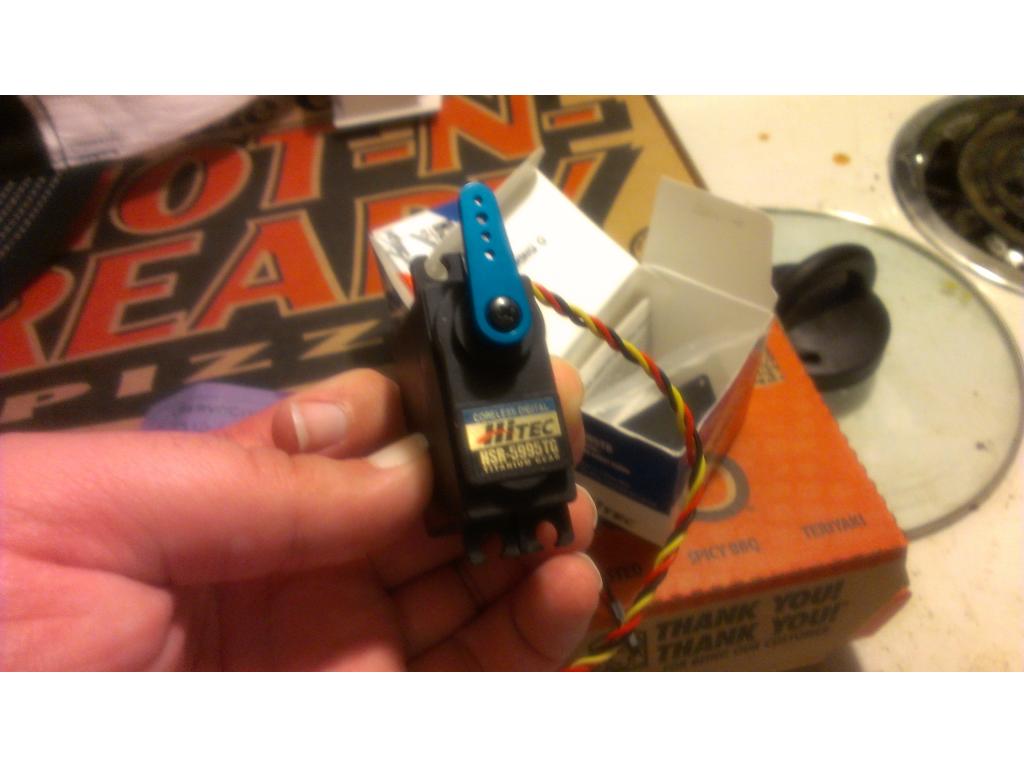
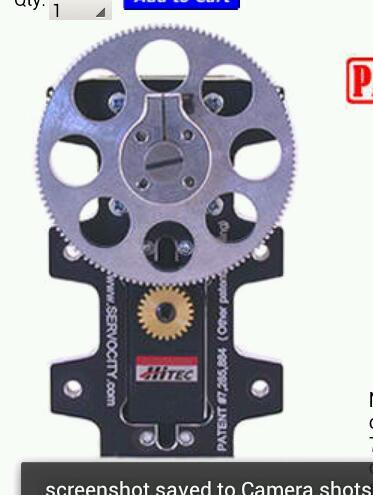
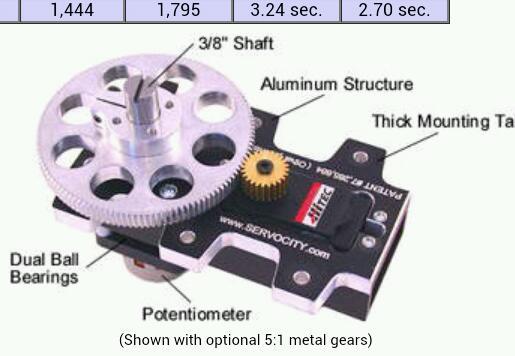
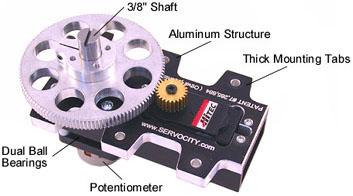
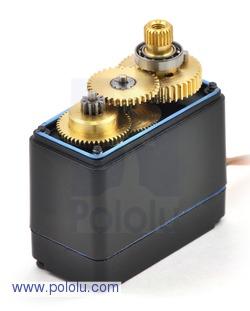
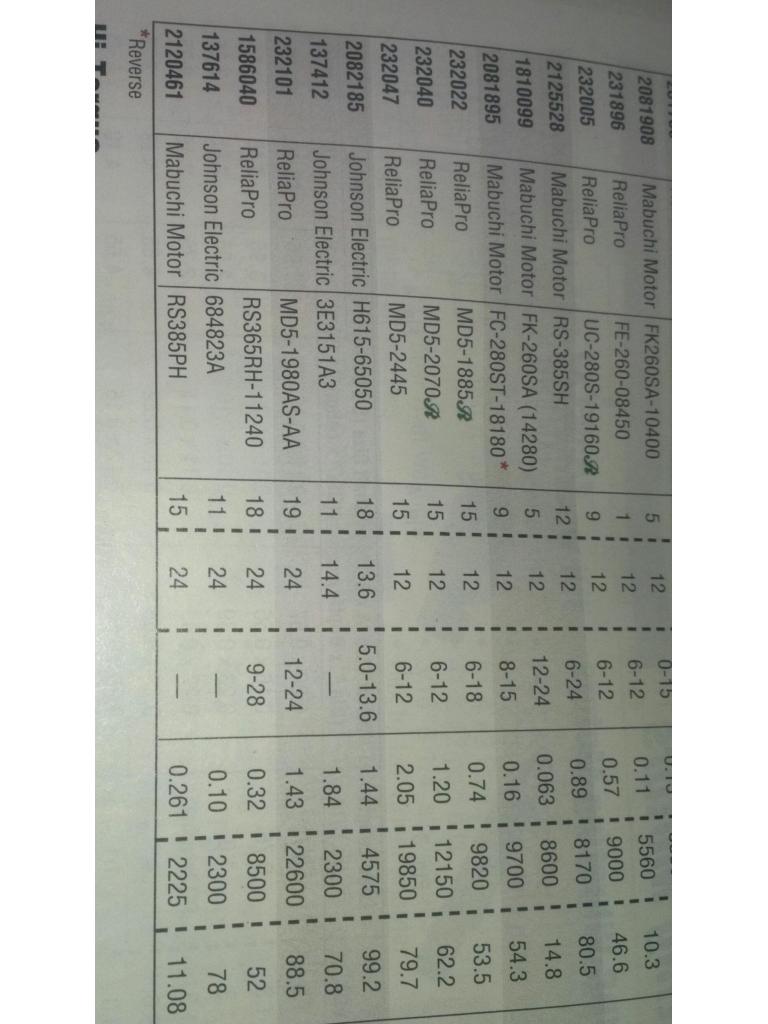
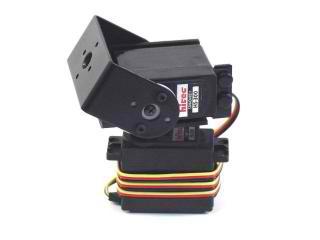
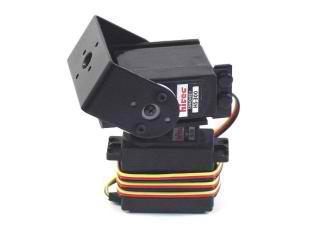
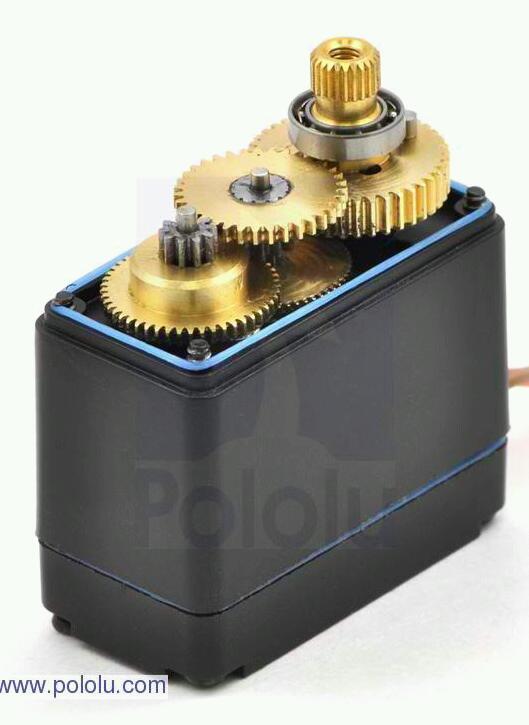
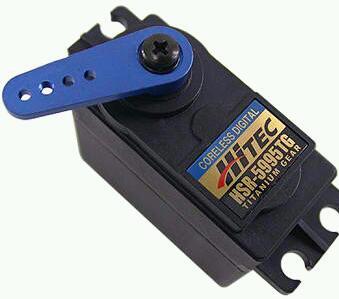
After looking at the option I.rather cast two gears and attach them to servo.horns and.use servos to.drive.the robot. I believe it will also make less noise too. I believe I would do 4wd , one servo for each wheel. Lucky me I can get drive servos later on lol. Tommorow I get to bondo the sides of risers and do some sanding. Well I correct myself , I must drill mounting holes first to ensure everything cannot move then do bondo lol , I've considered using a couple hsr 5995tg servos because those guys are monsters. , or maybe those pololu power gf 240 oz in servos would work fine? I guess due to this being my first robot.I don't.know the torque figure I should shoot for with a 50 pound bot.
Have you looked at the Tamiya Gearbox?
Thanks Sam , those are not strong enough
I think you'd be surprised at how strong they are but you could also use two. They are pretty compact.
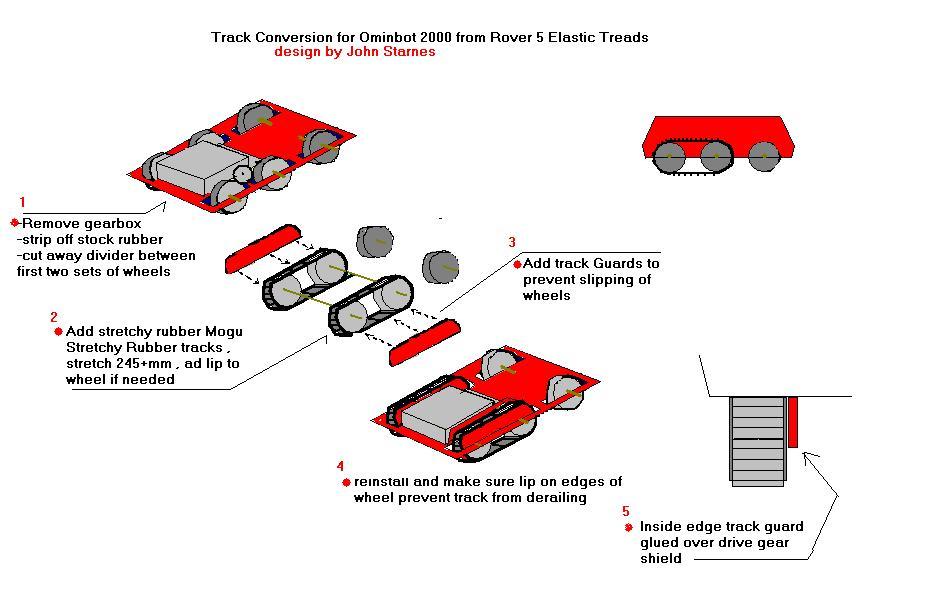
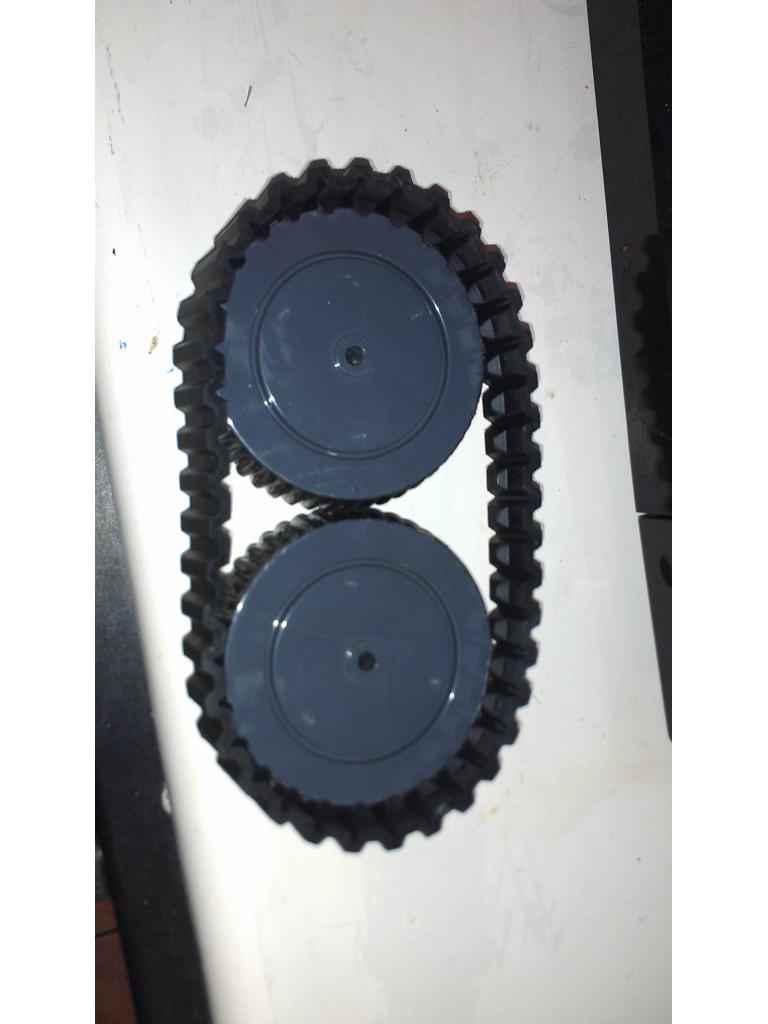
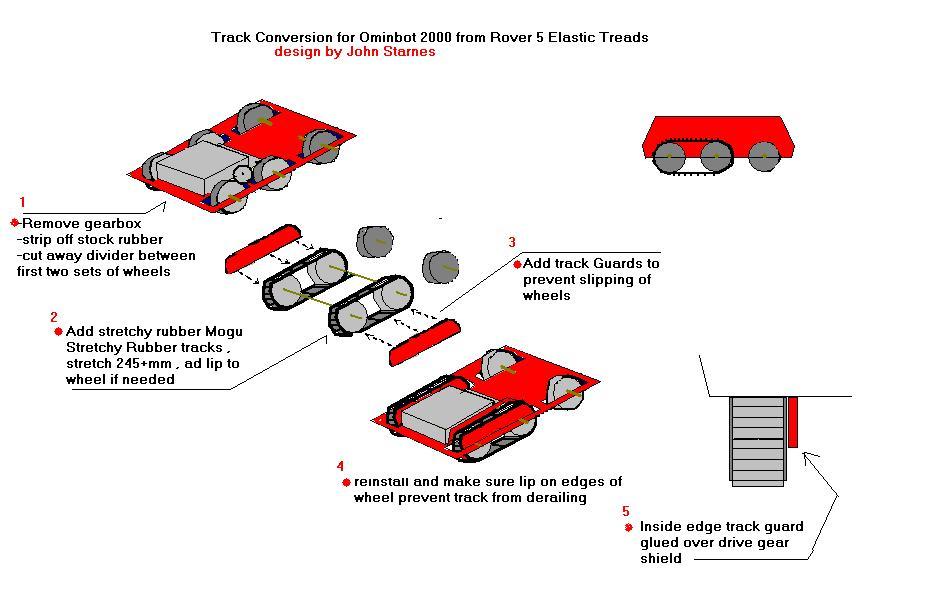
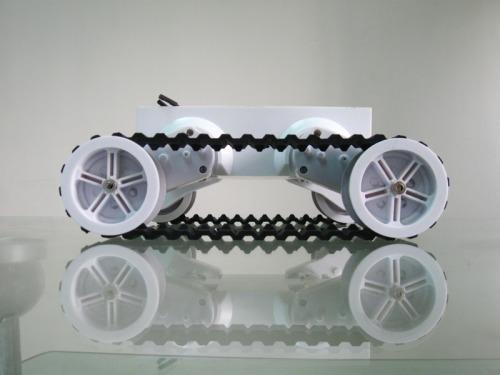
i thought the gear box would not work,why not the design i use (tracks design) it hold a lot more then 70 lbs with 4 high torque motors
Boy it sucks to run into drive issues this late in the build. I feel your pain. What about using gear motors? They have a gear head attached and are super high torque. Plus you can run them off your motor controller. One motor with gearhead for each drive wheel.
sorry, josh. That is a heartache. But, don't give up. Jarvis will be up and running in now time.
Hang in there.
keep trying dude,dont give up