

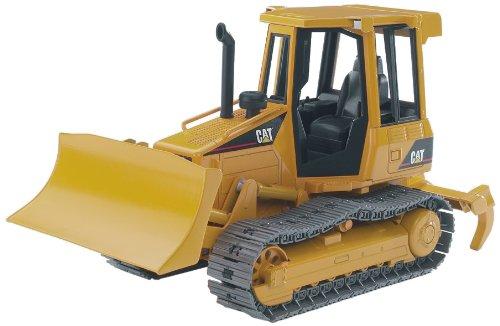
I got my EZ-Bot last week and this weekend I started with my first project. I got myself a nice Caterpillar toy:
And, as far as I can tell from other posts here, in good EZ-Bot tradition, started to disassemble it right away.
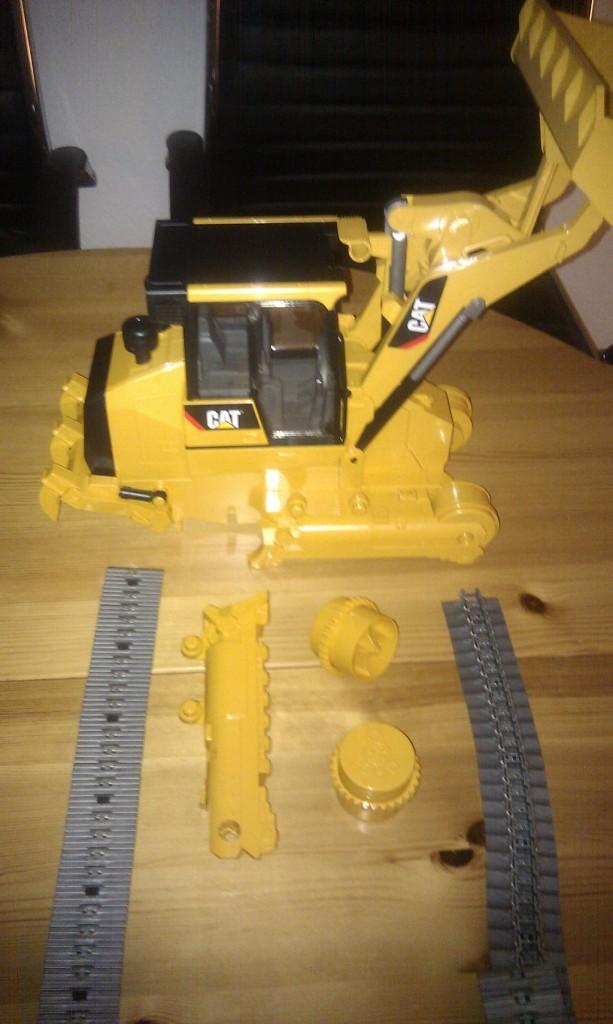
After just slight problems with dremeling, I cut a hole in the bottom for the continuous servos that will drive the treads. I couldn't believe how close the servos fit in there.
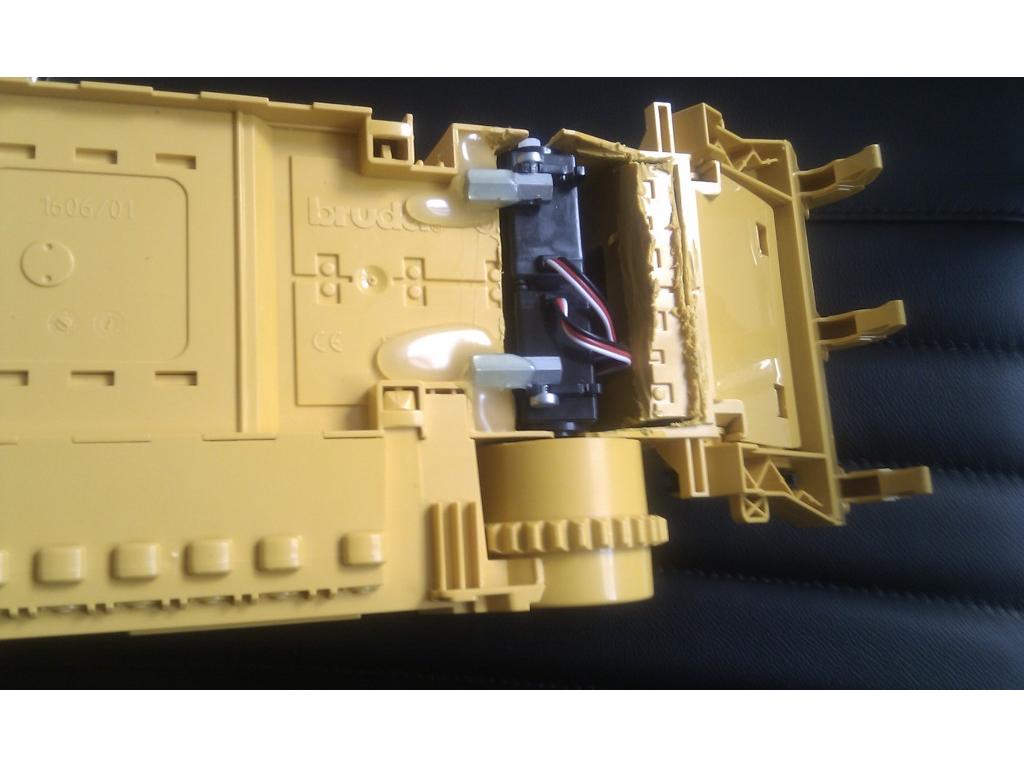
Hotglue the servo horn to the driven wheels
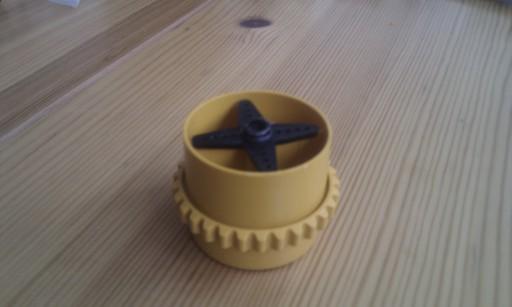
A hole for the cables into the cabin and we're good to go!
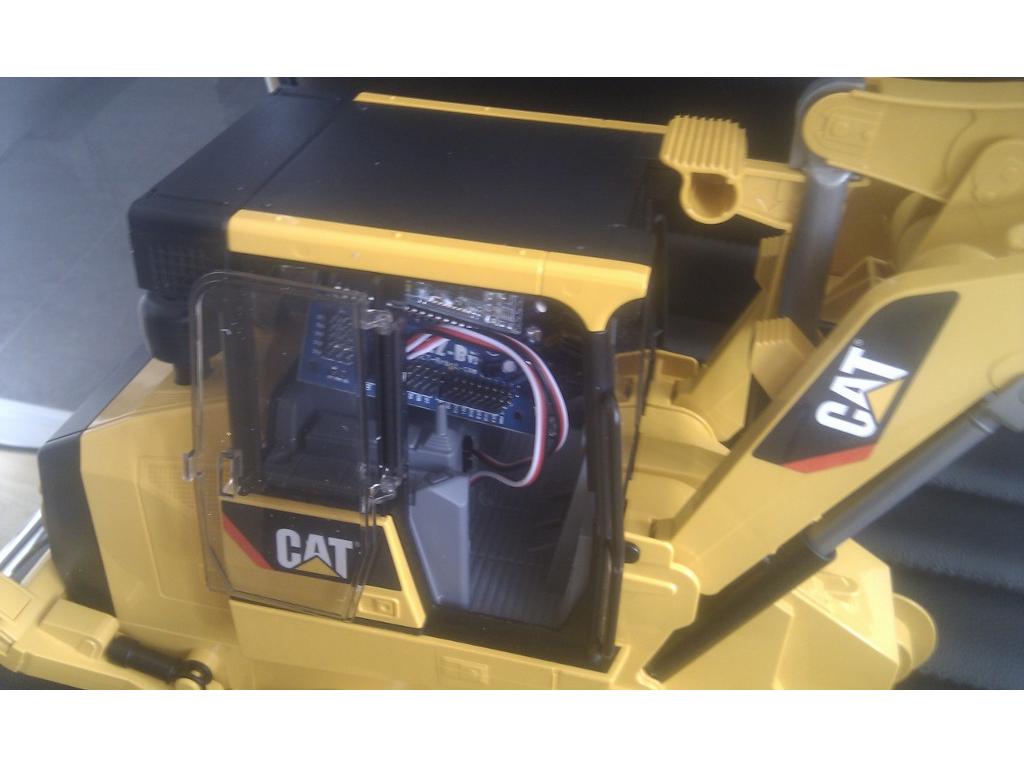
By peterfrisch
— Last update

Discover more robots
Steve's Navigation Test Robot With Intel Realsense T265
Navigate an iRobot Create using Intel RealSense T265 and EZB with Synthiam ARC for reliable visual tracking navigation...
Rgordon's Project Questor
Questor: compact autonomous test robot with EZ-B control, camera 'nose', IR LEDs, remote-control option and...
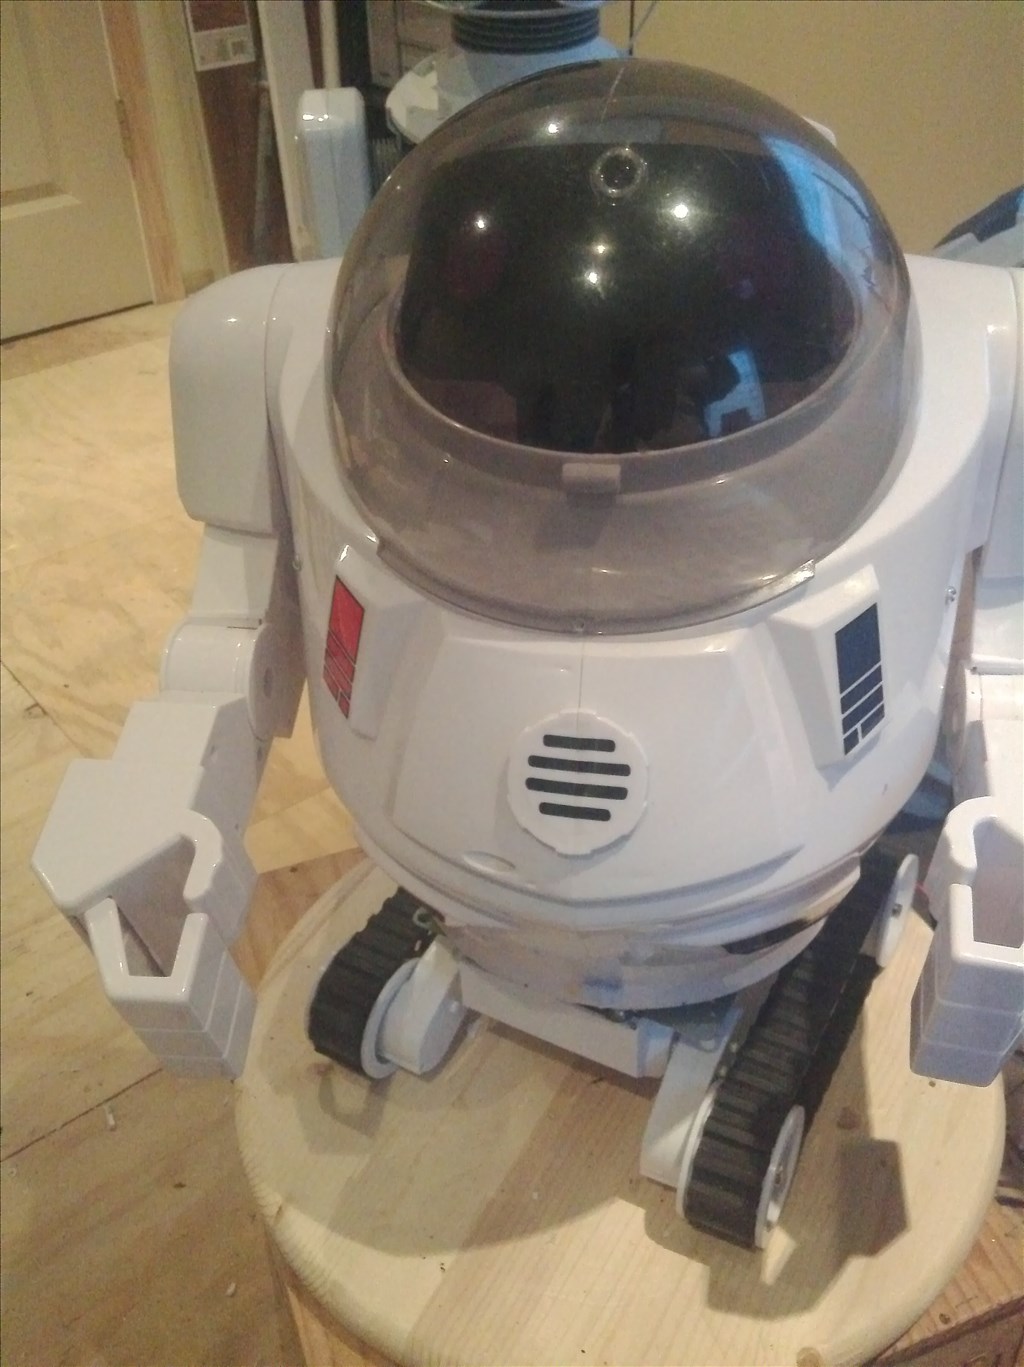
Rb550f's Ez Robot Rover
Custom robot with clear dome head, EL tape neck lighting and ezb backpack repurposed from an alarm clock; updated photos...

Sorry, we go off the forum for the german discussion.
As a short summary: Sven and me both have problems with the voice control. The commands are just not recognized. Sven thought it might be because of his german win 7, but I use an english one, so that's probably not the reason. On the other hand: I got very few commands through to my bot, while none of Svens were recognized. So in my case it might just have been a bad microphone, where in Svens case it seems to be a more fundamental problem.