
cE9s4PsOgeBQIORwjd5!~~60_1-634818020230156250.jpg)



Lupuc4g~~60_35-634706297915000000.jpg)


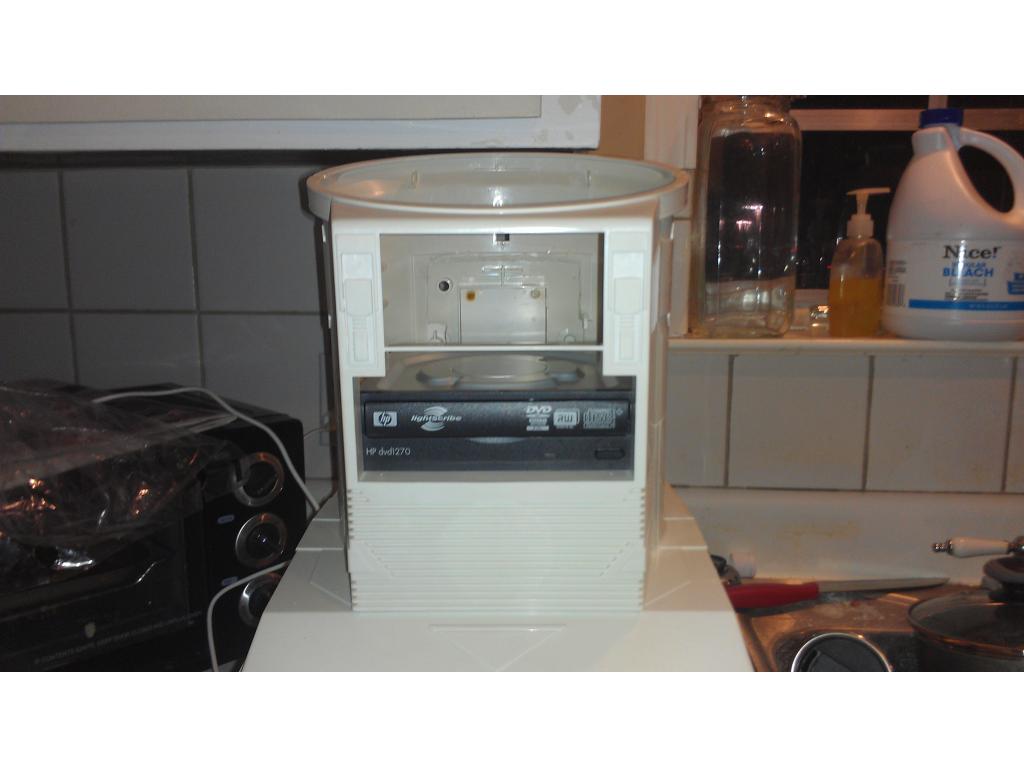
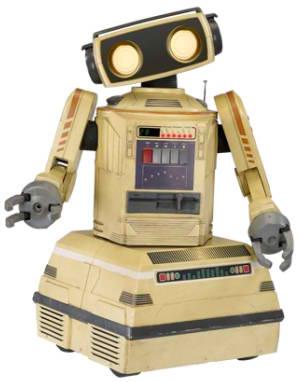
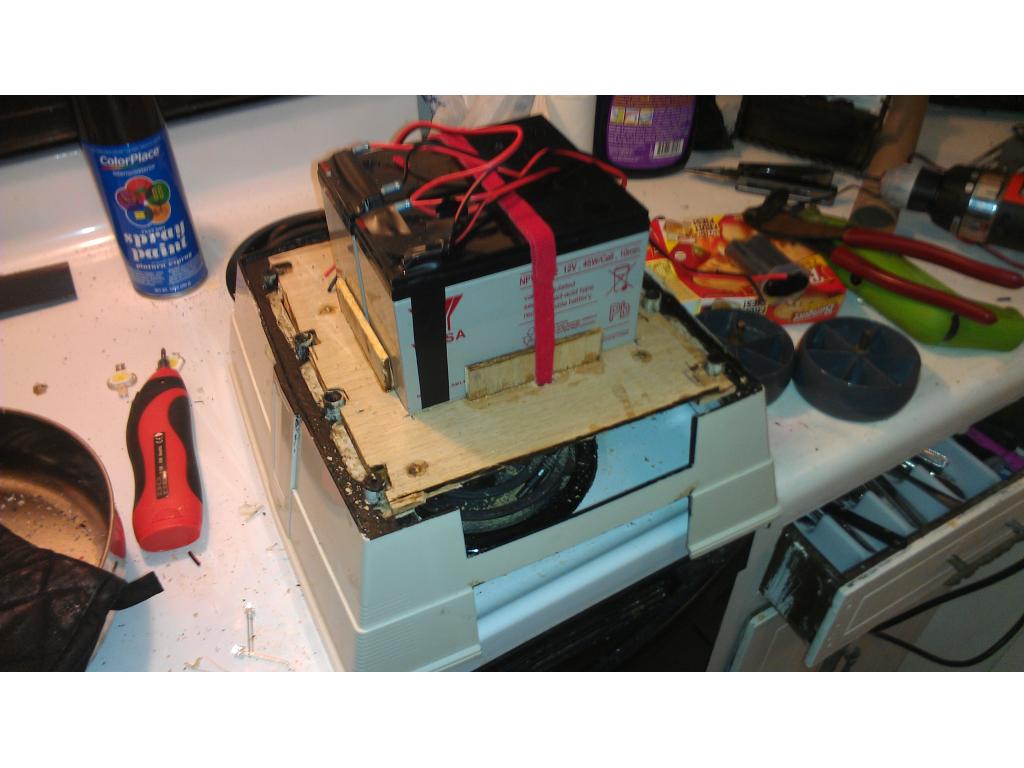

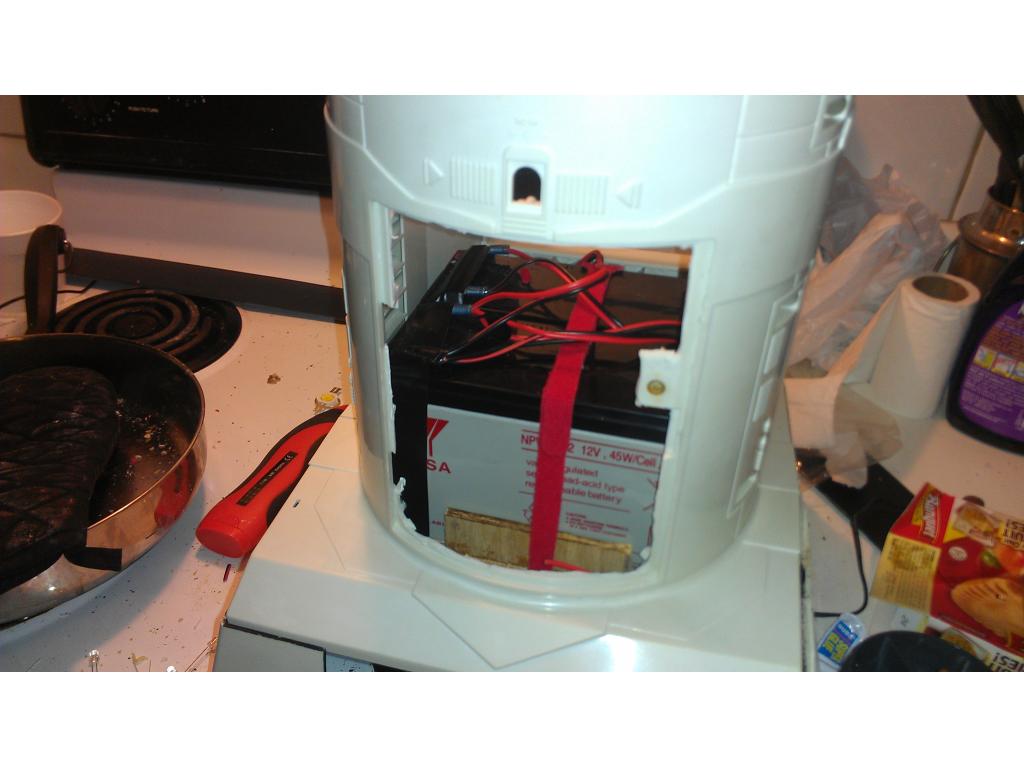
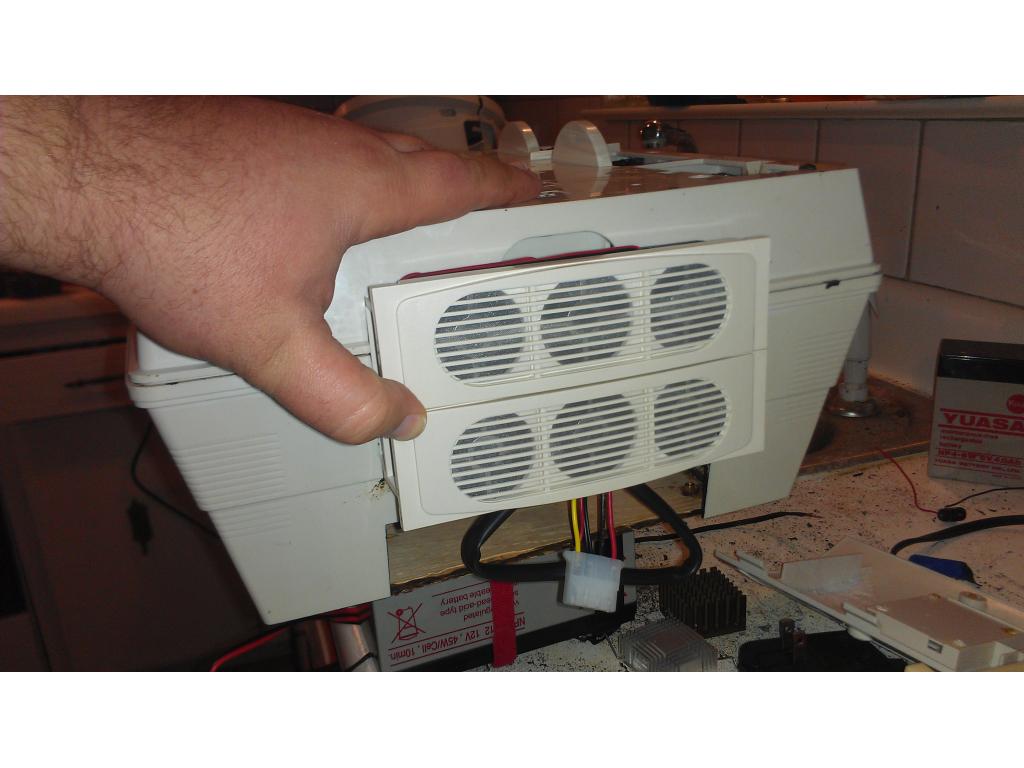
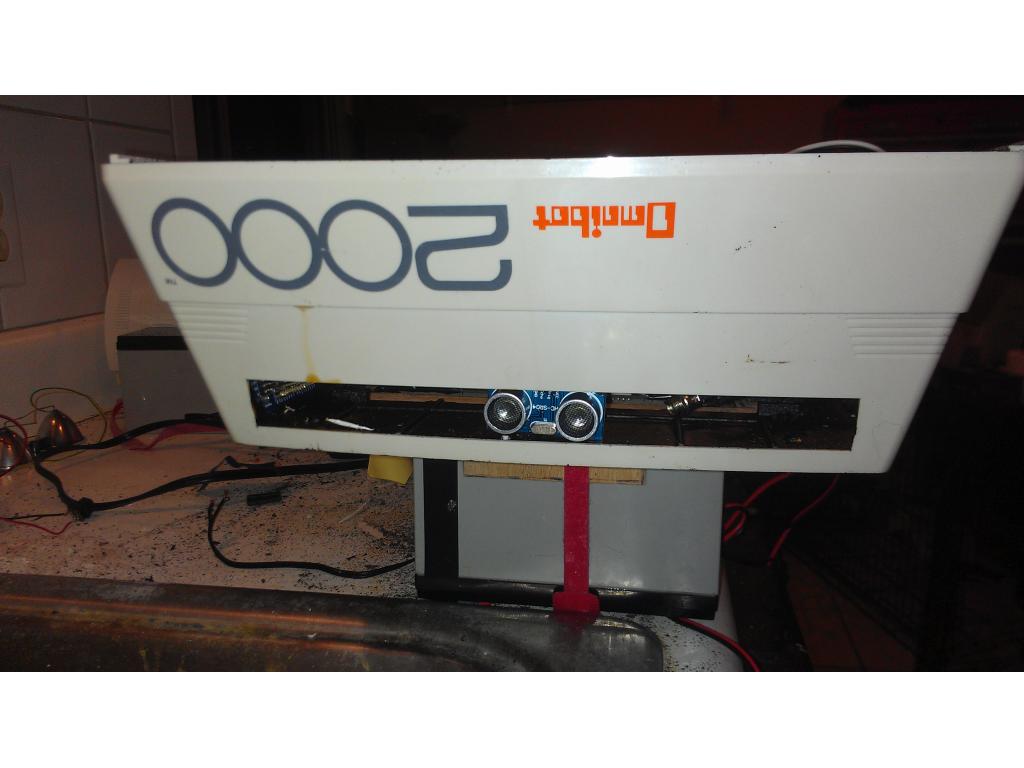
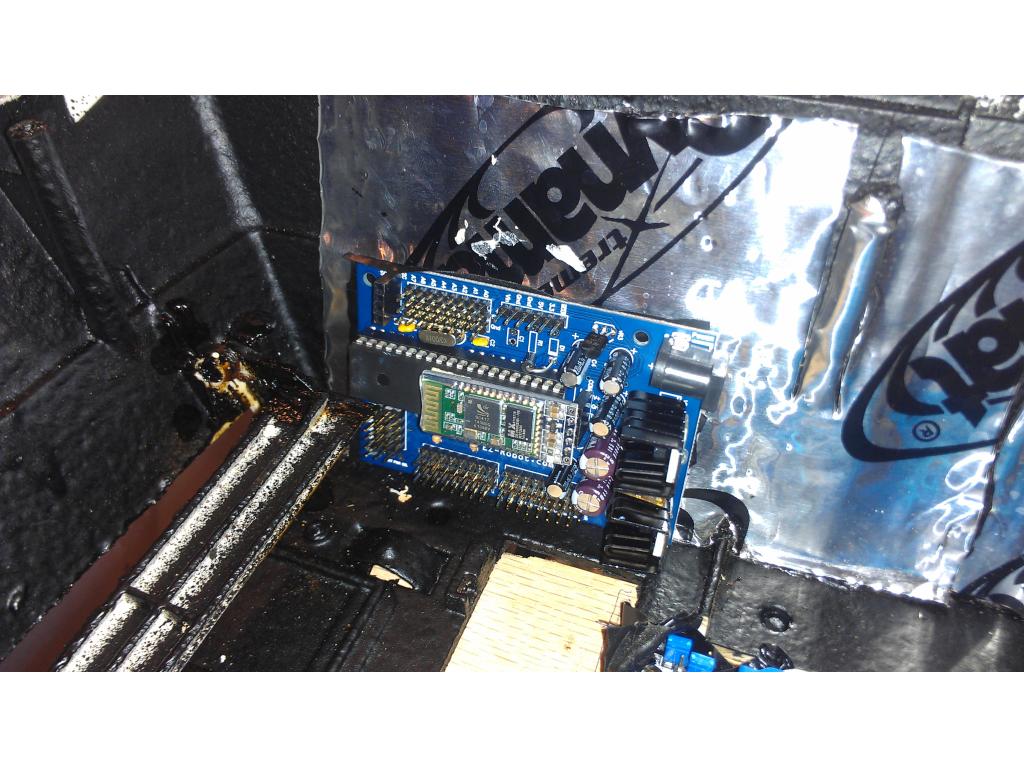
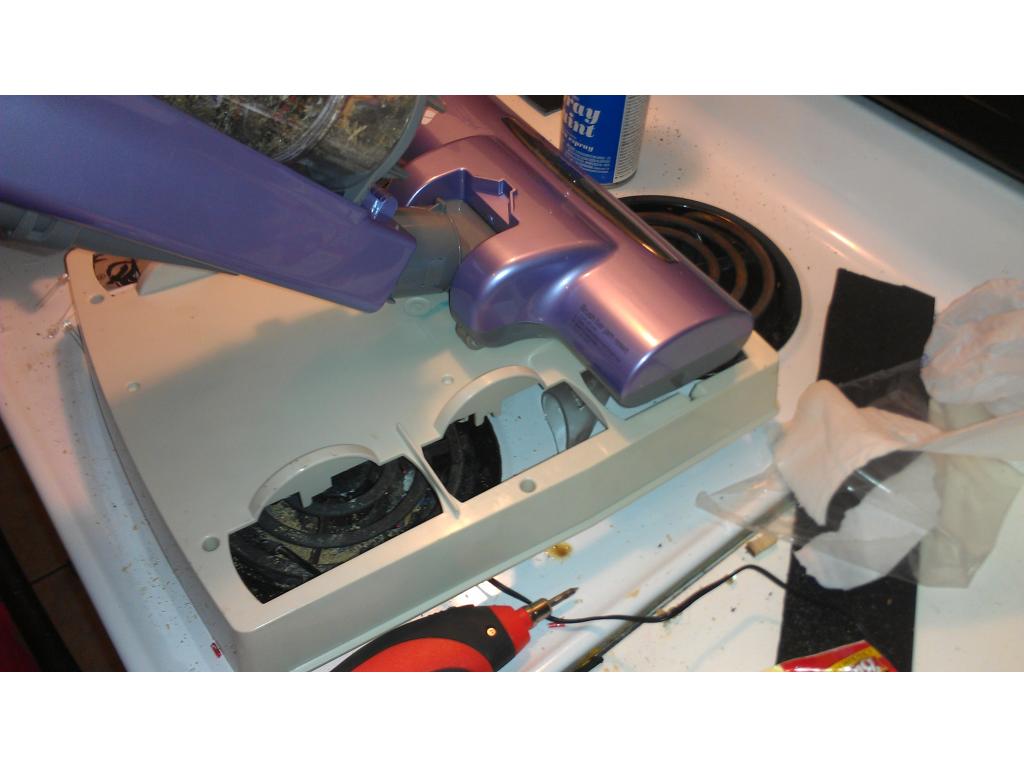

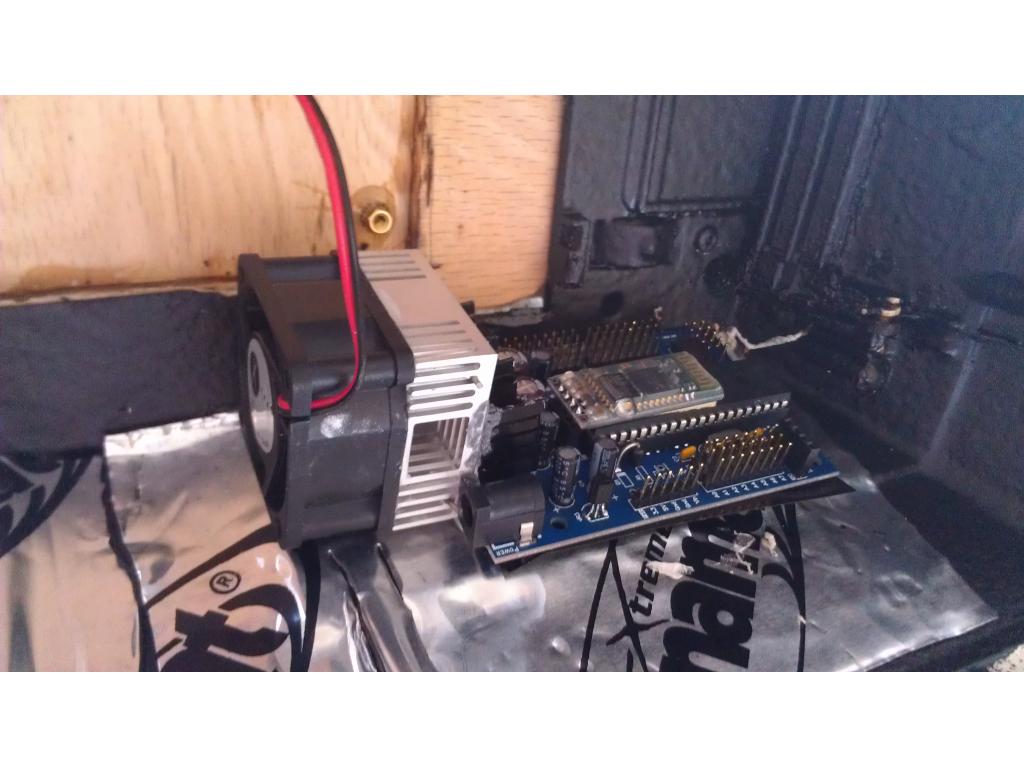
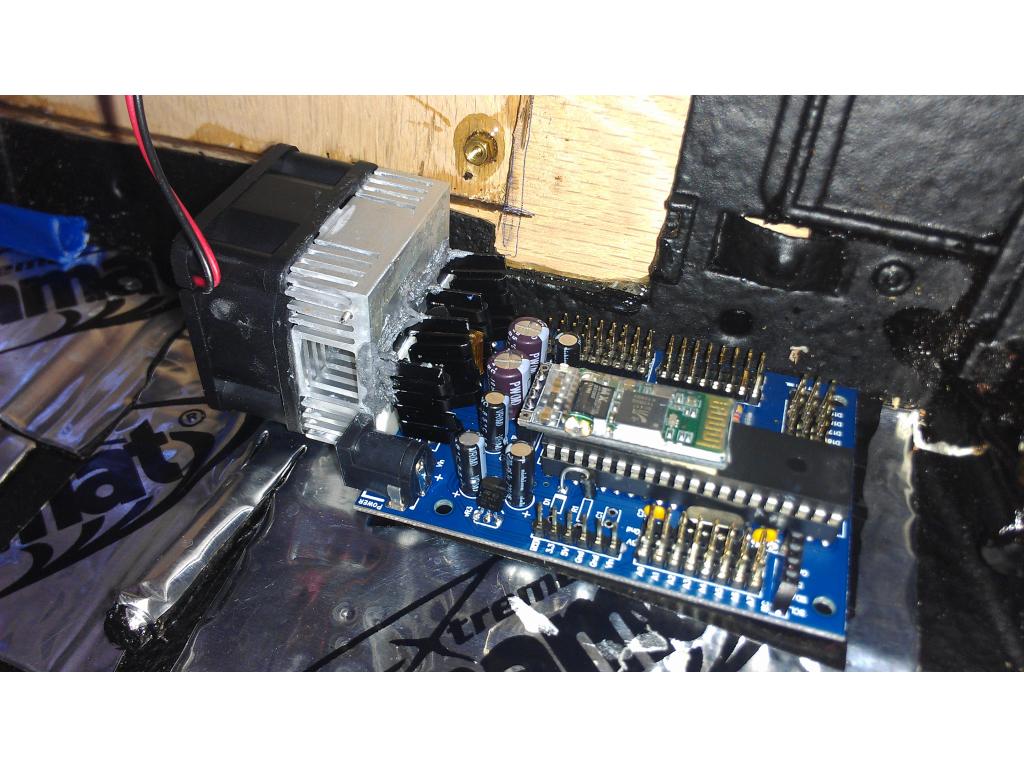

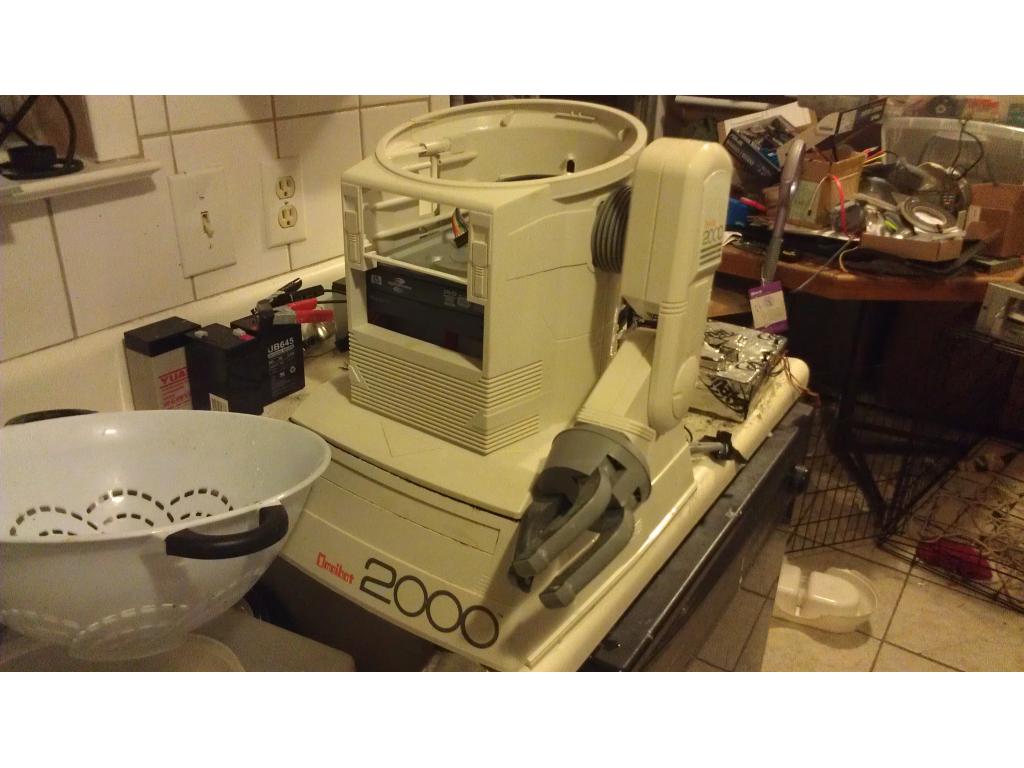
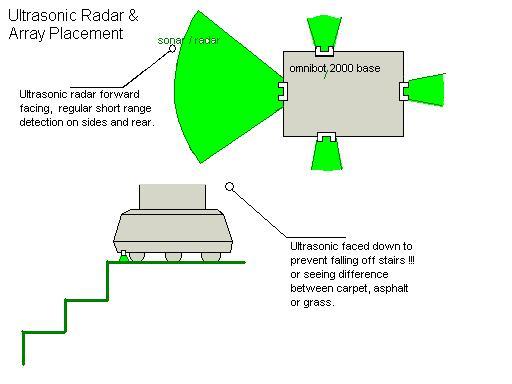
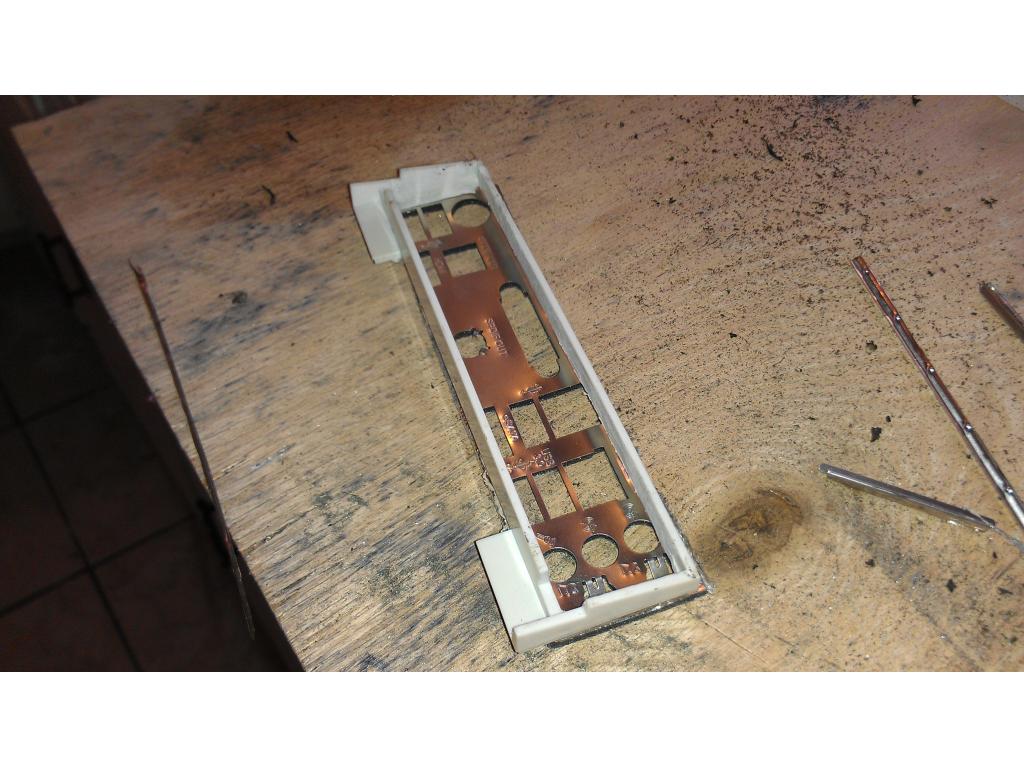
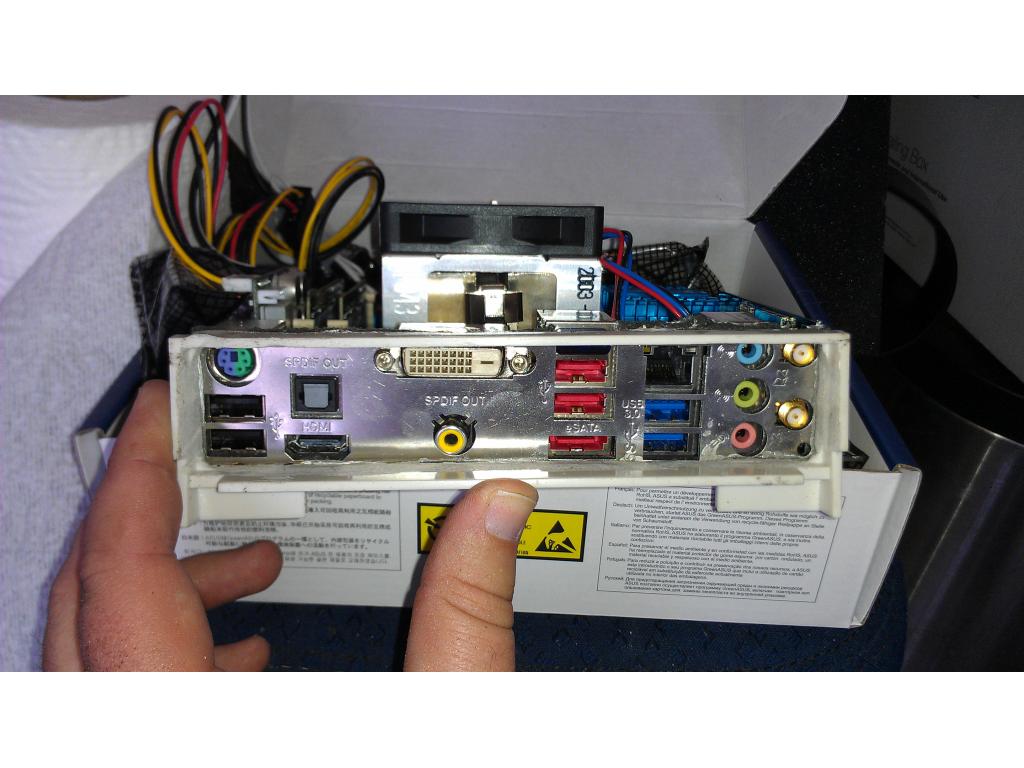
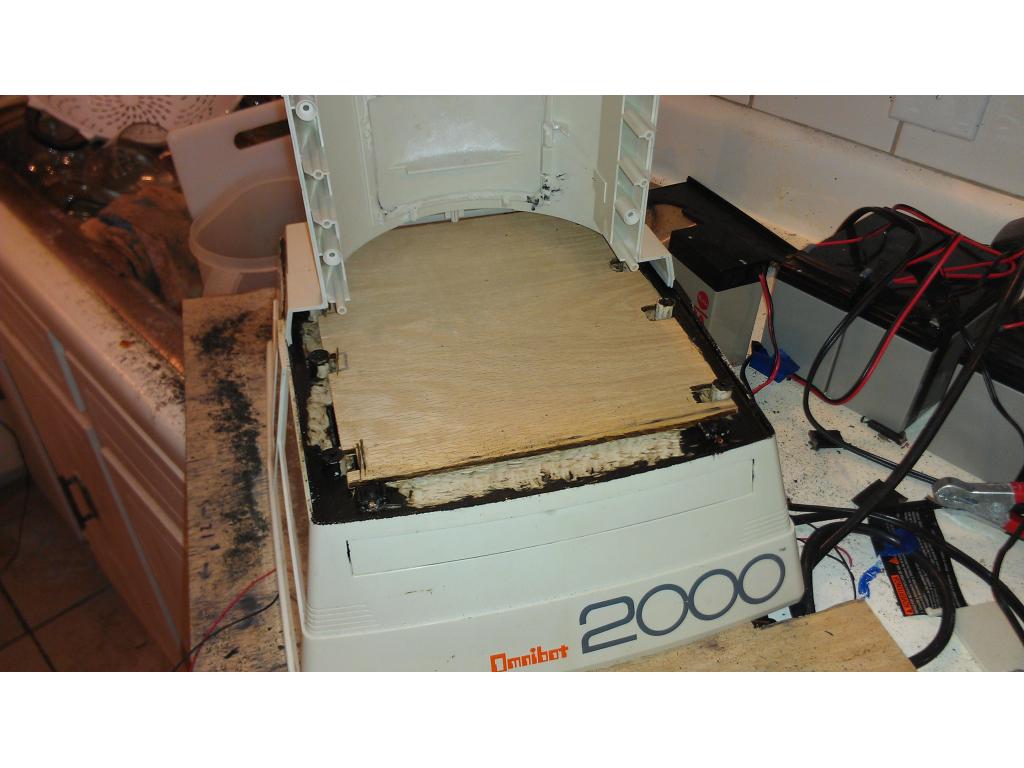
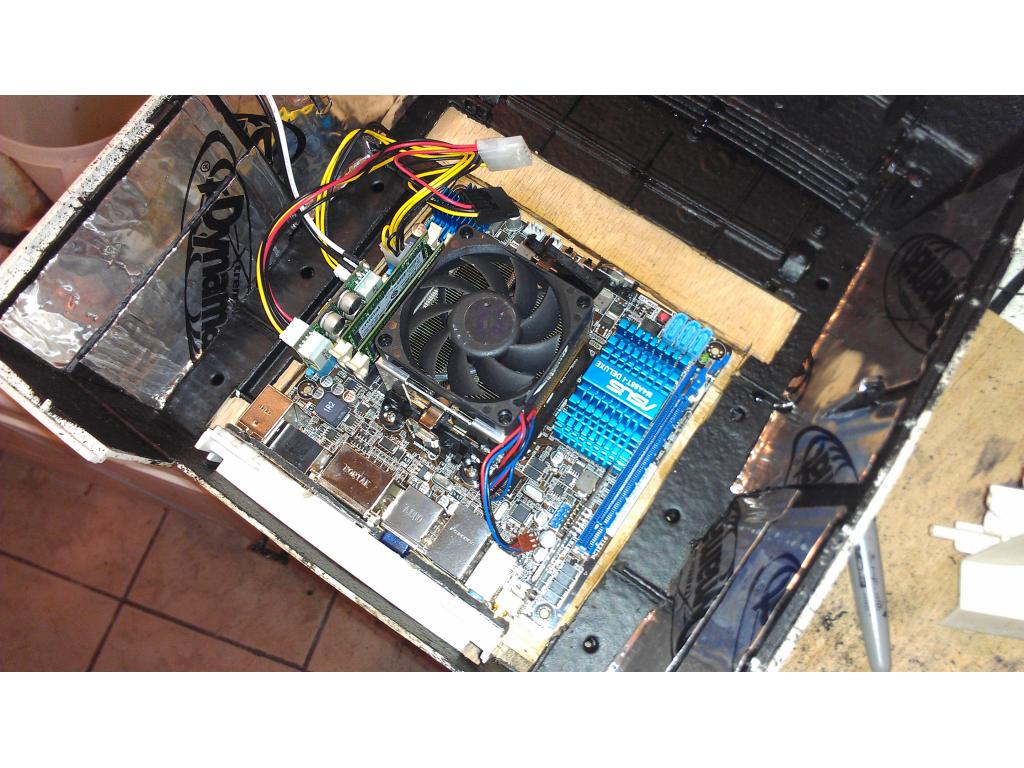
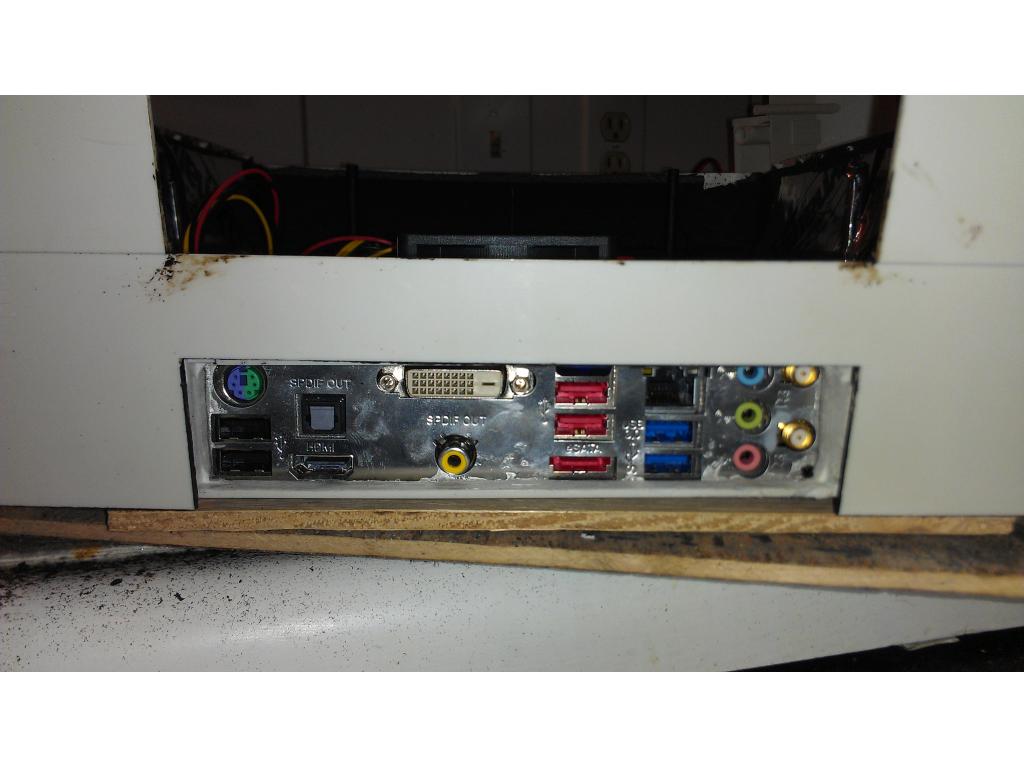
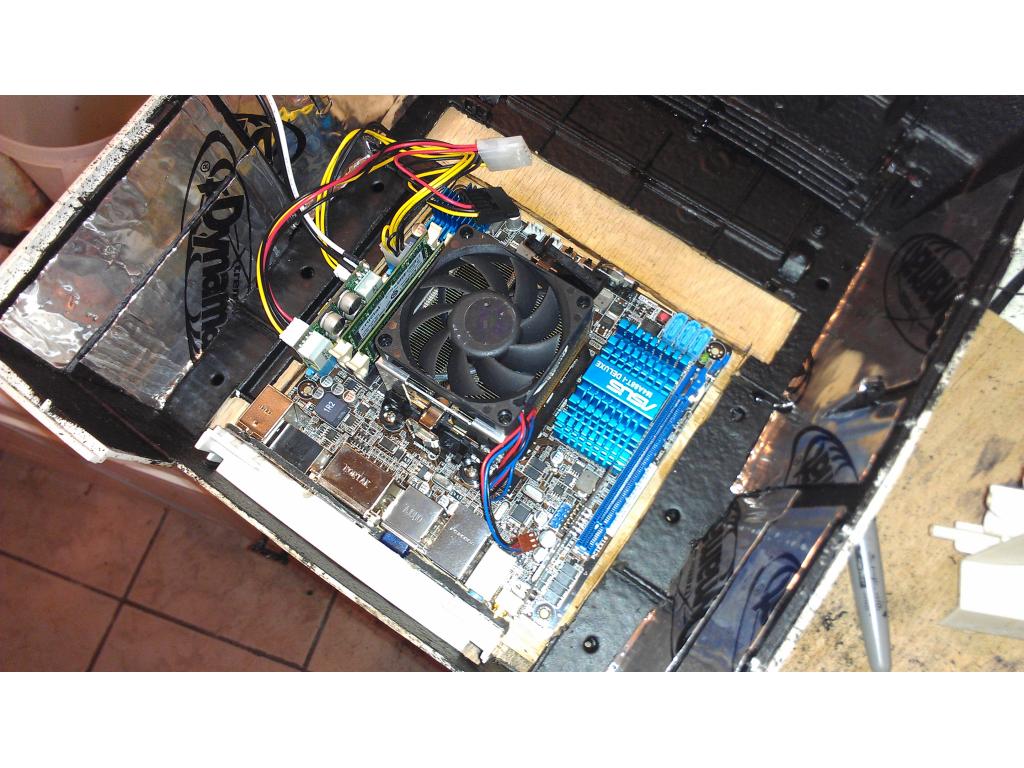
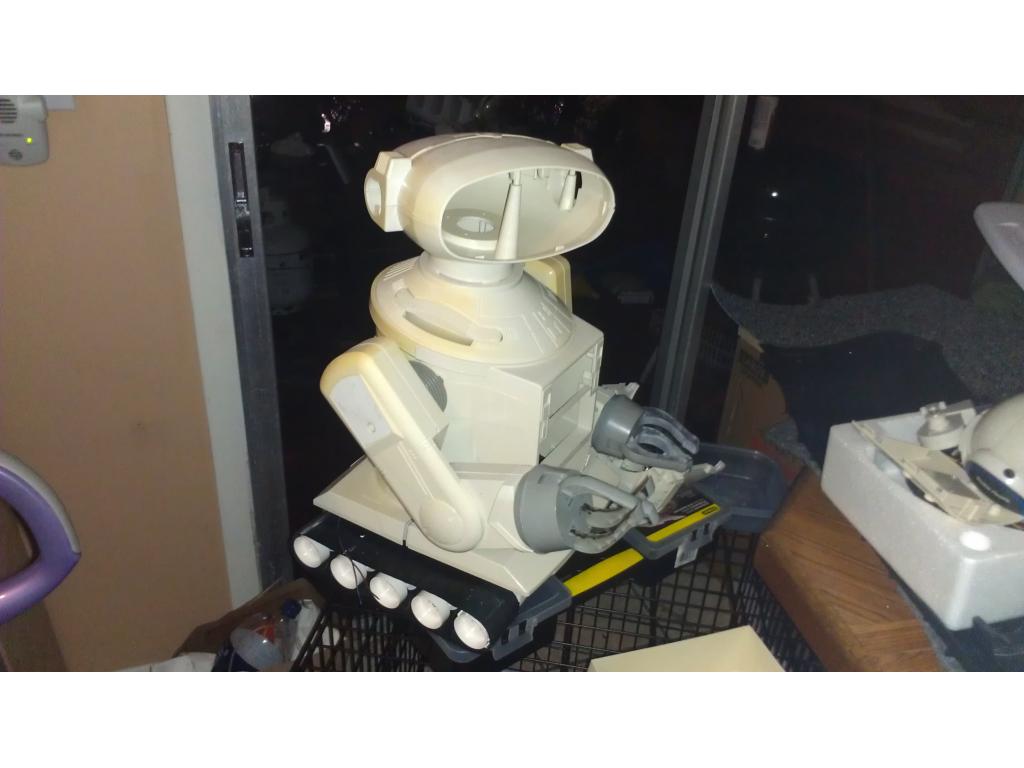
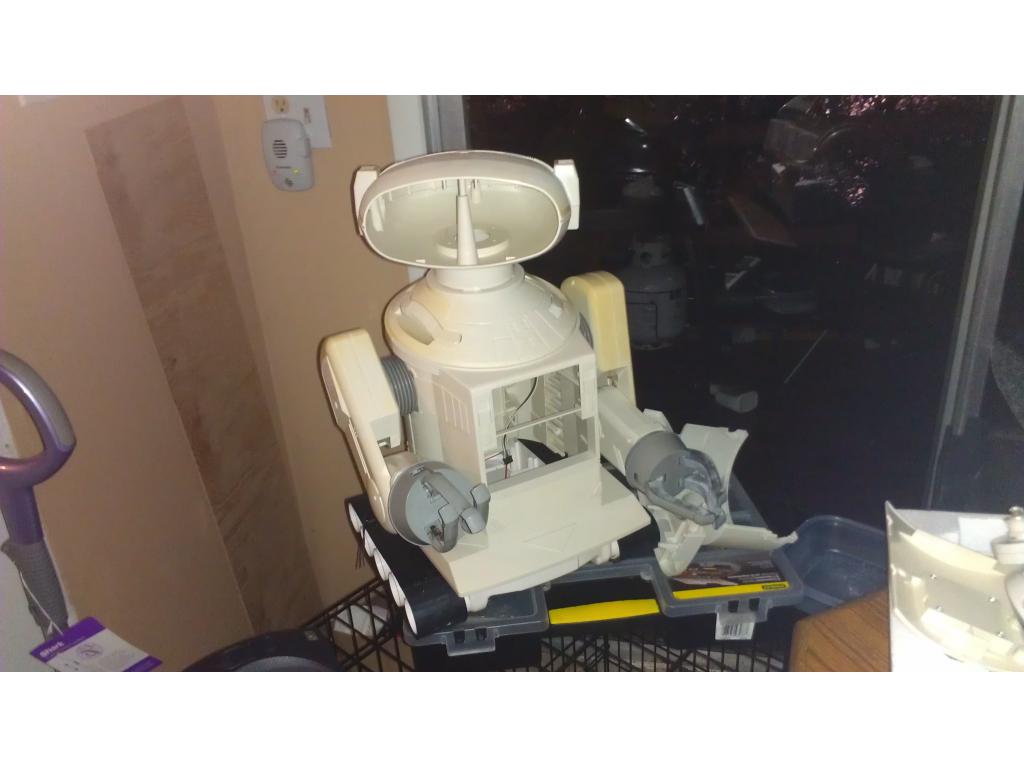
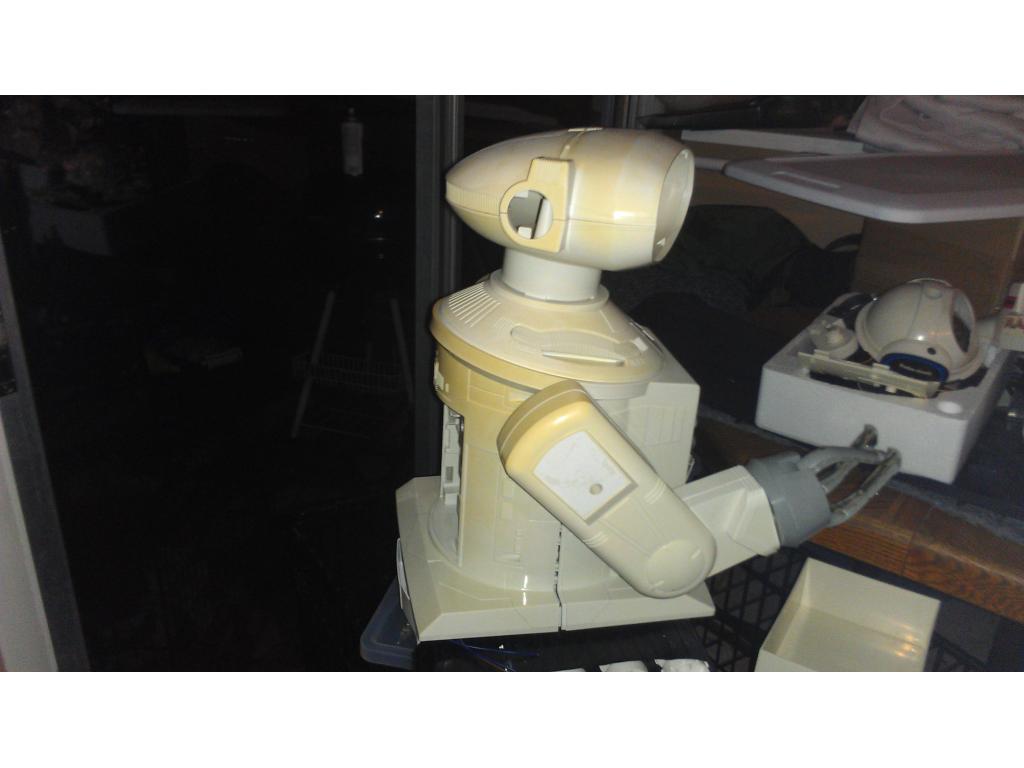
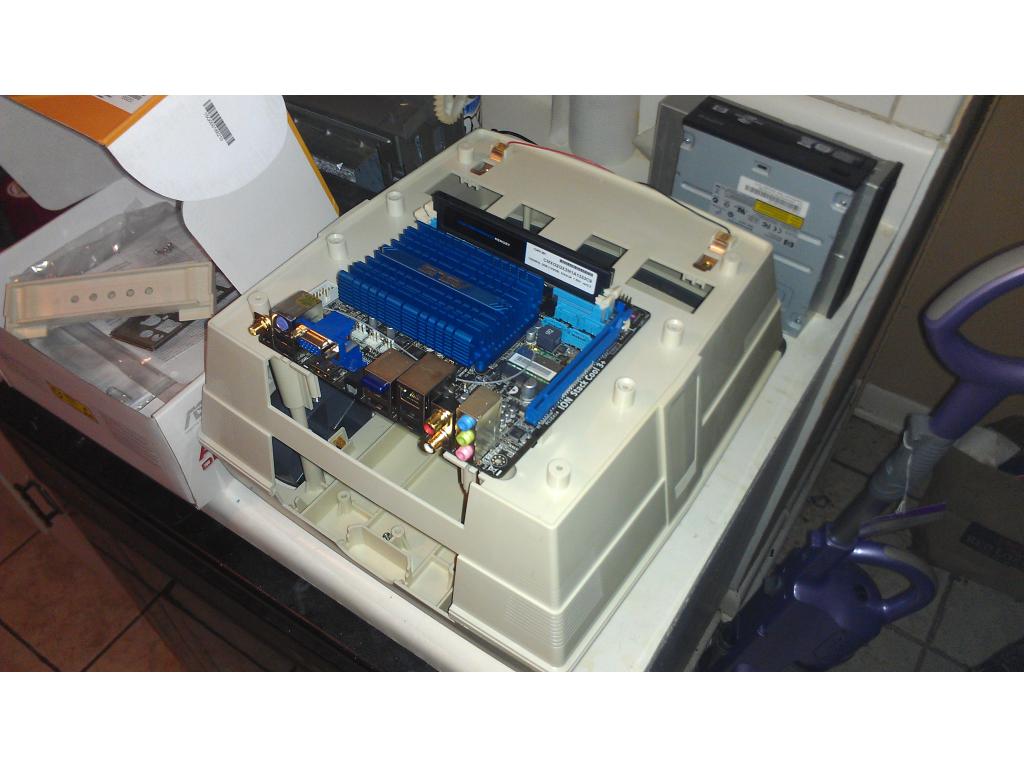
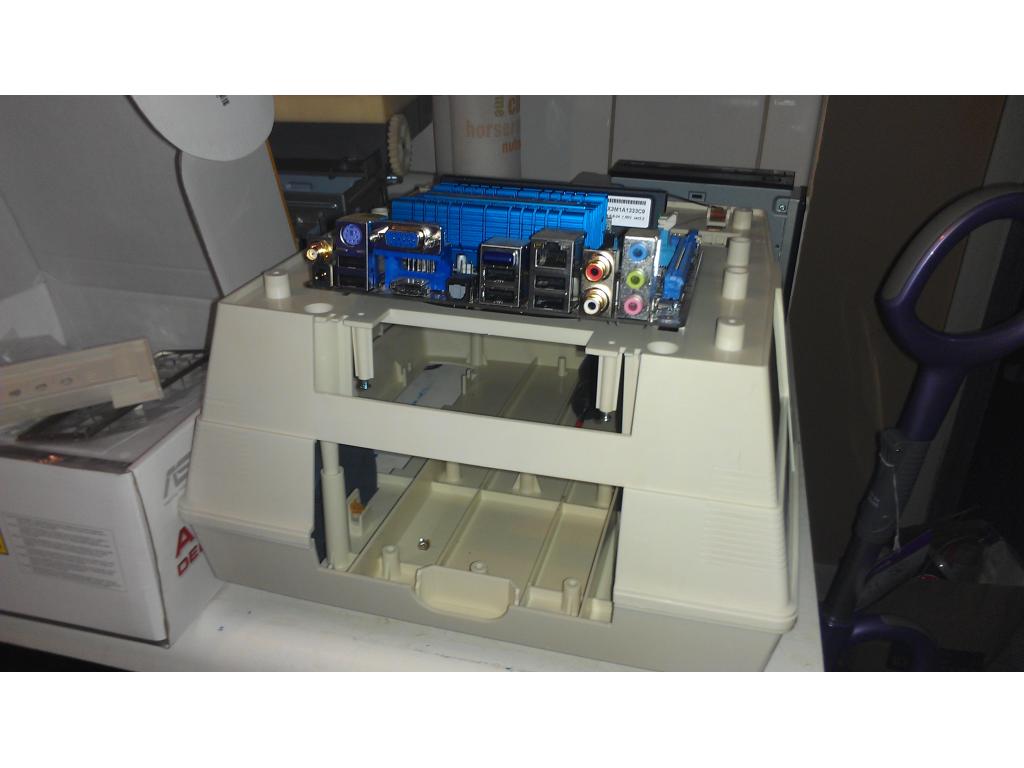
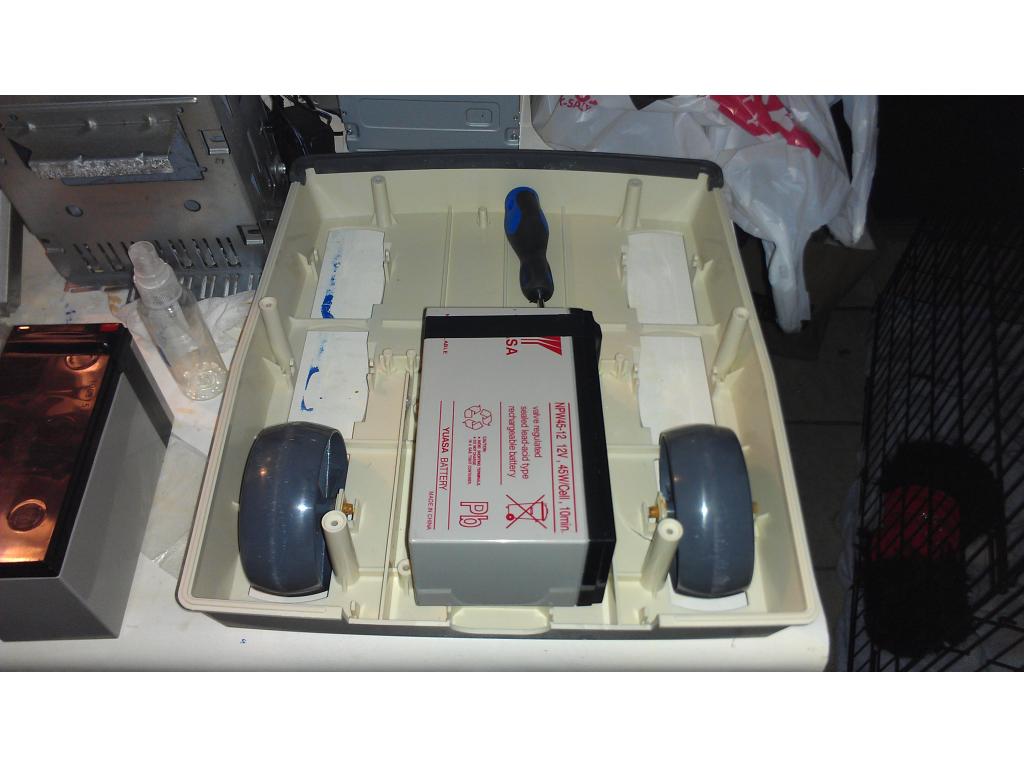
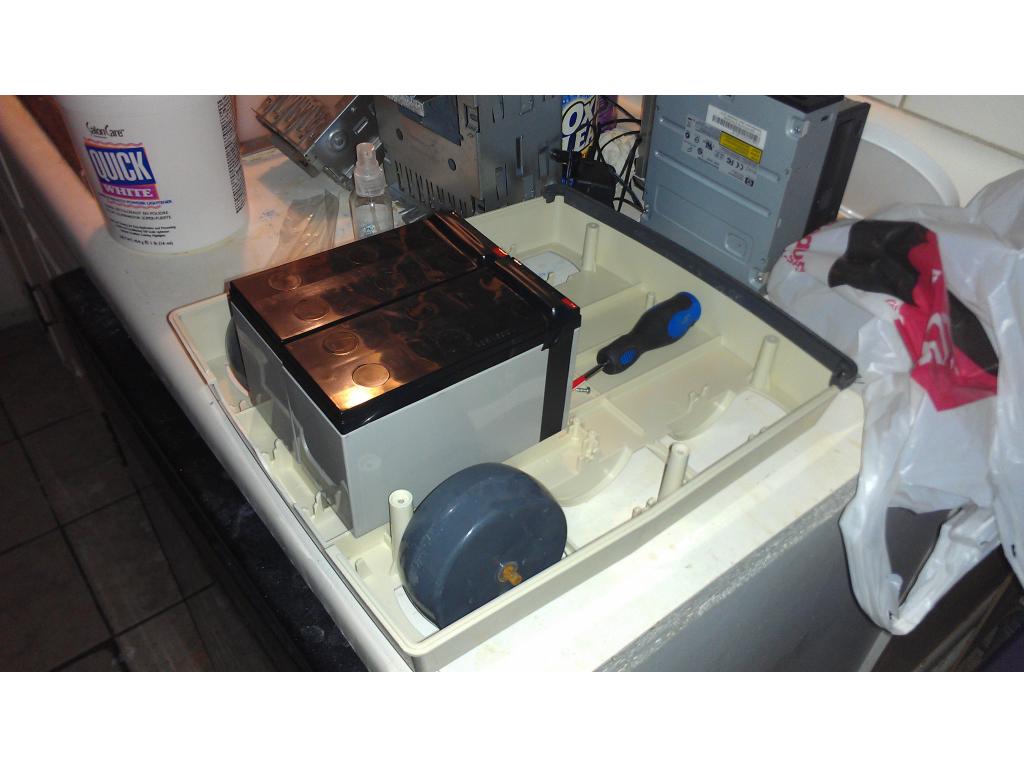
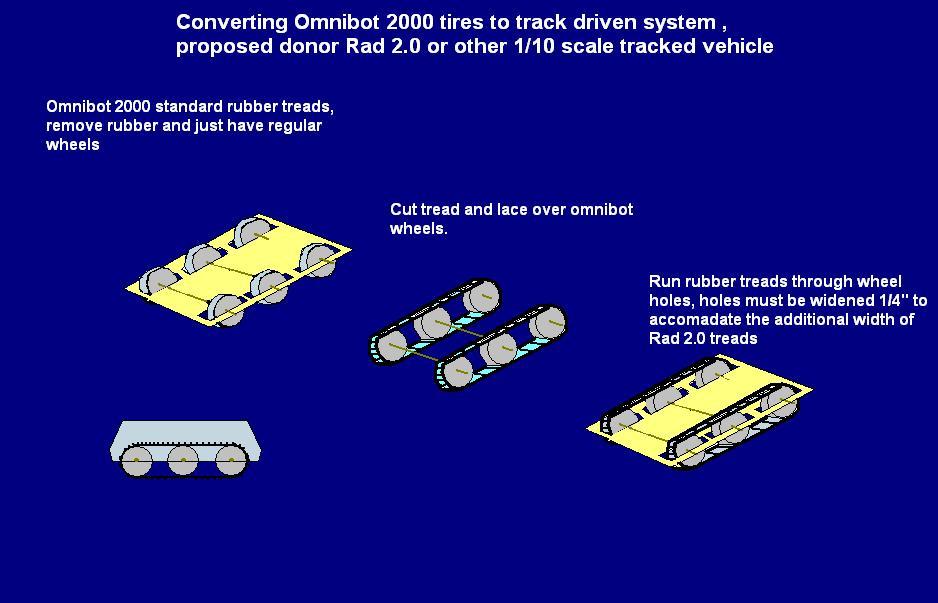


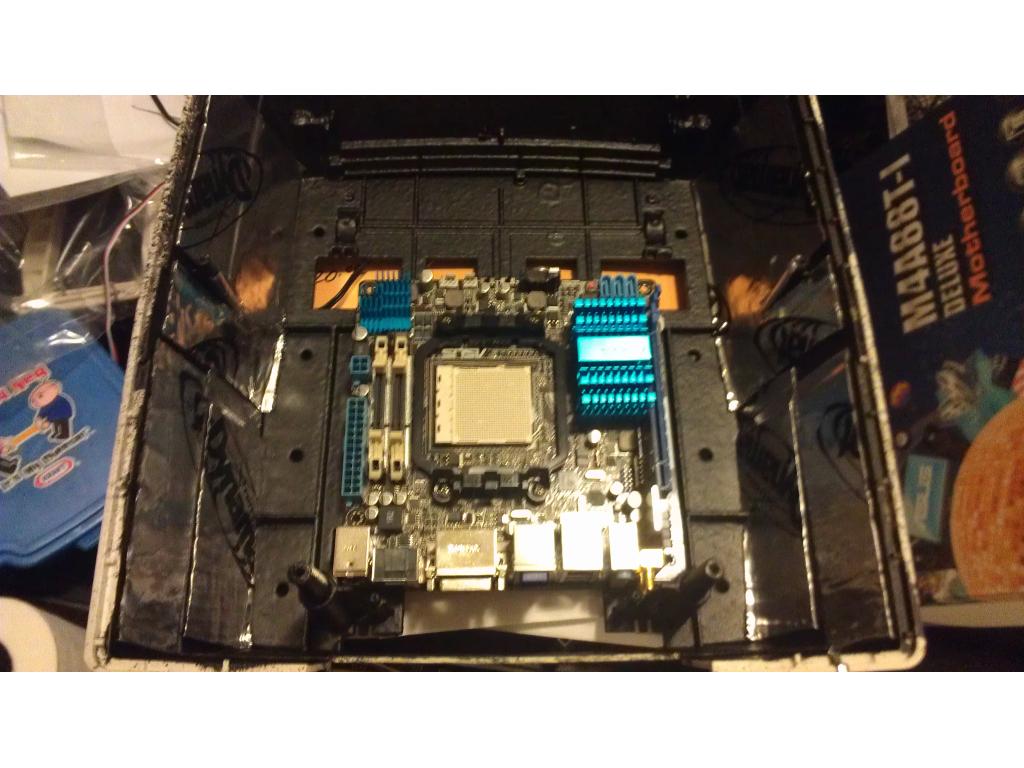
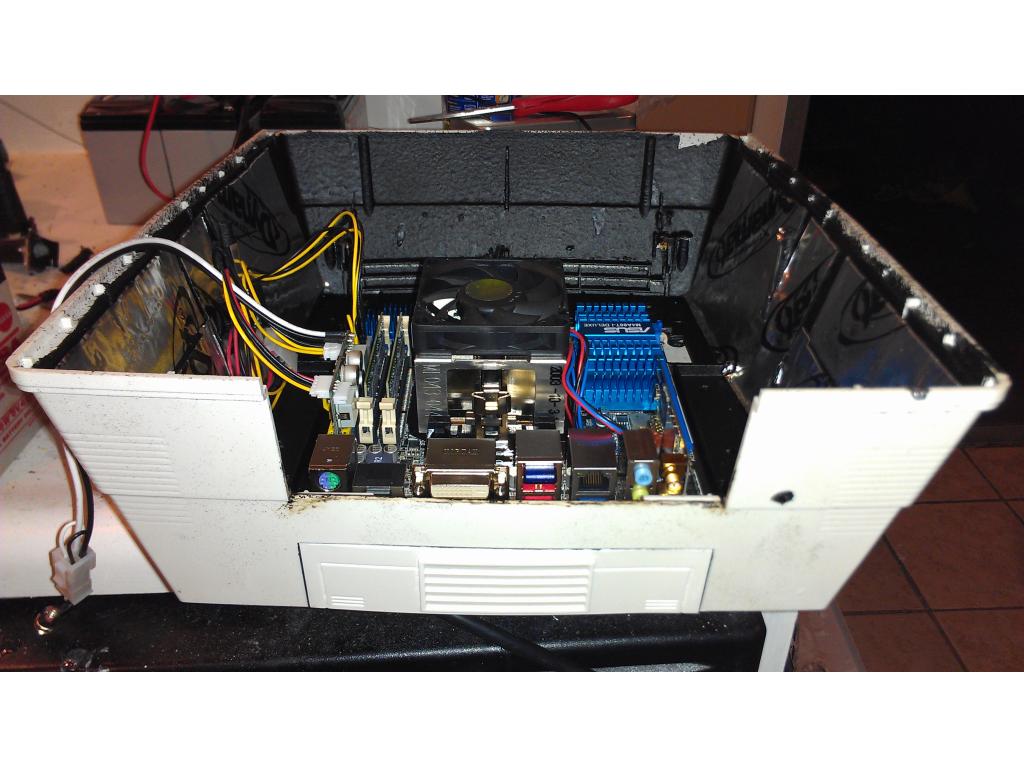
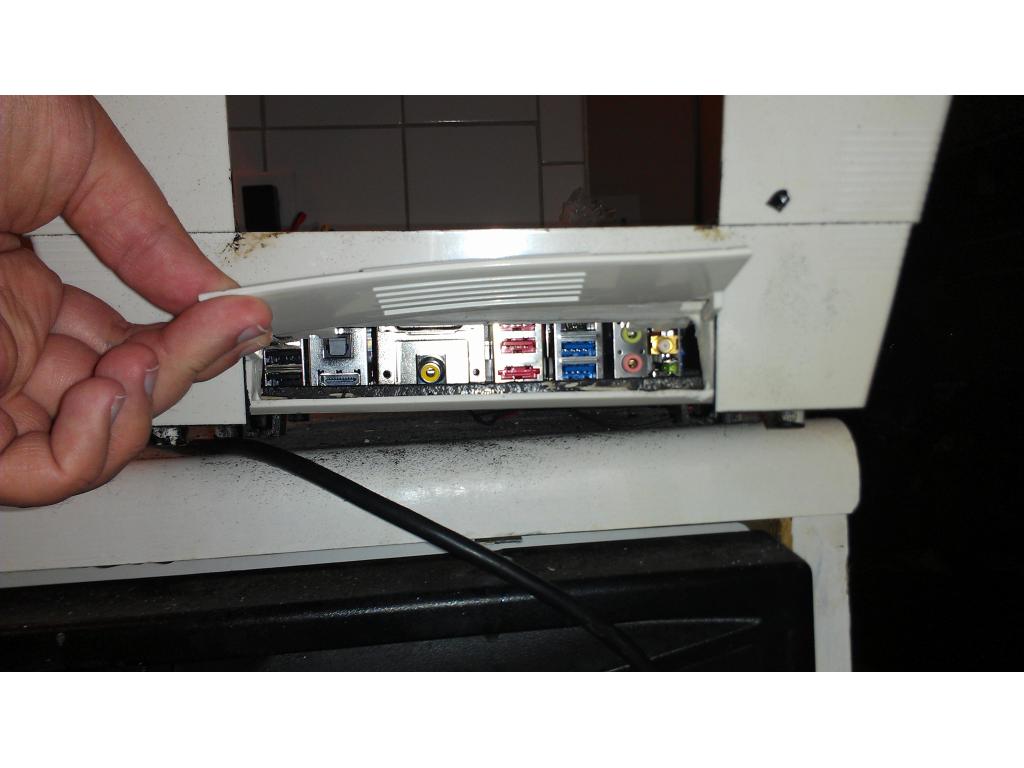
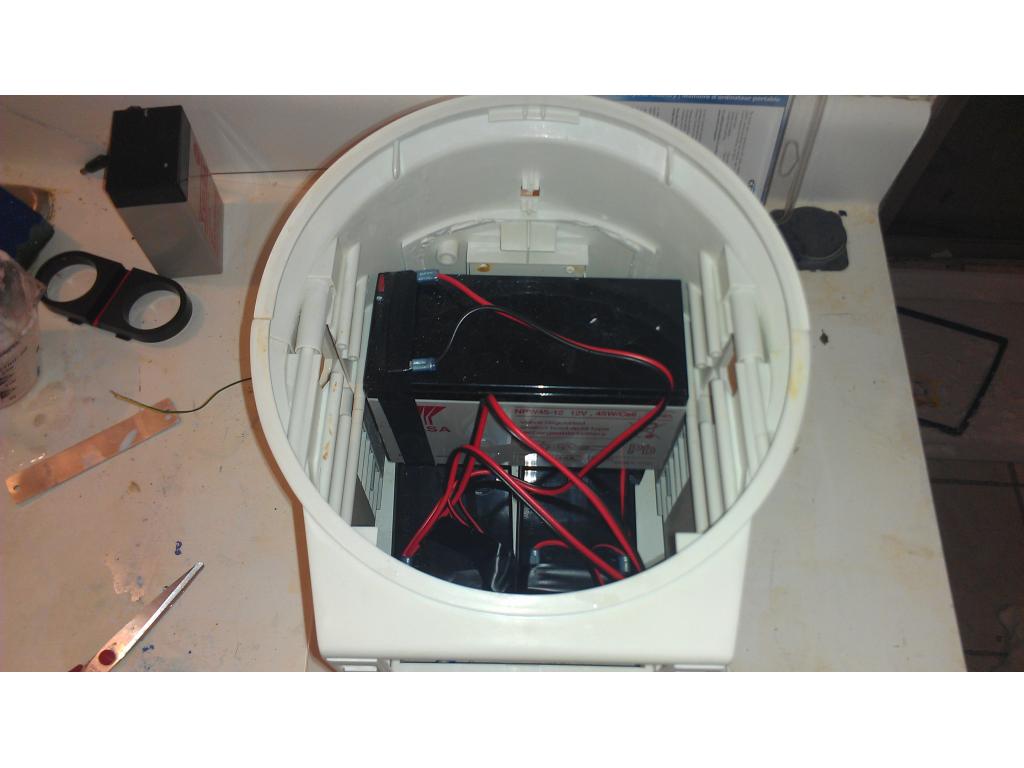
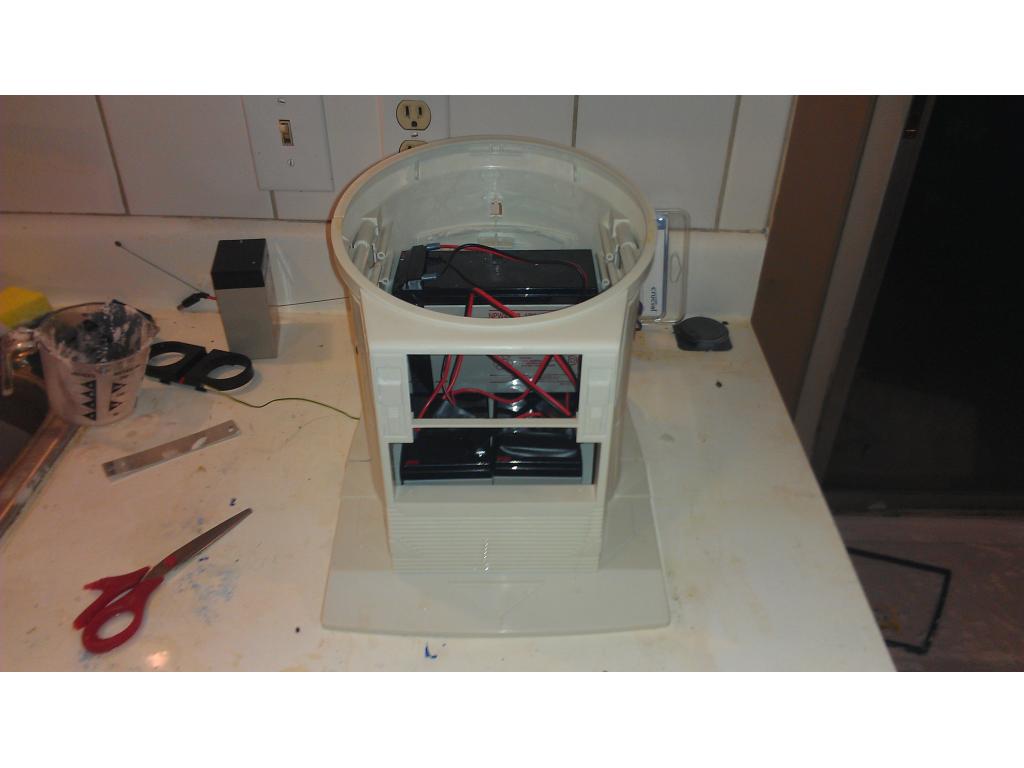
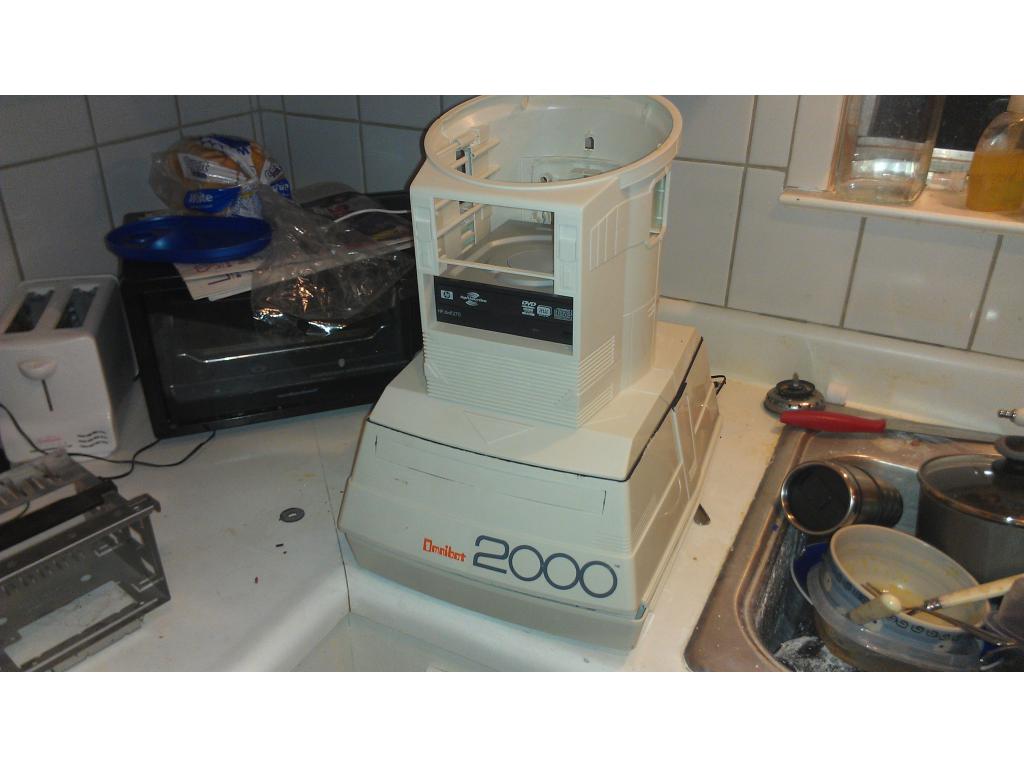
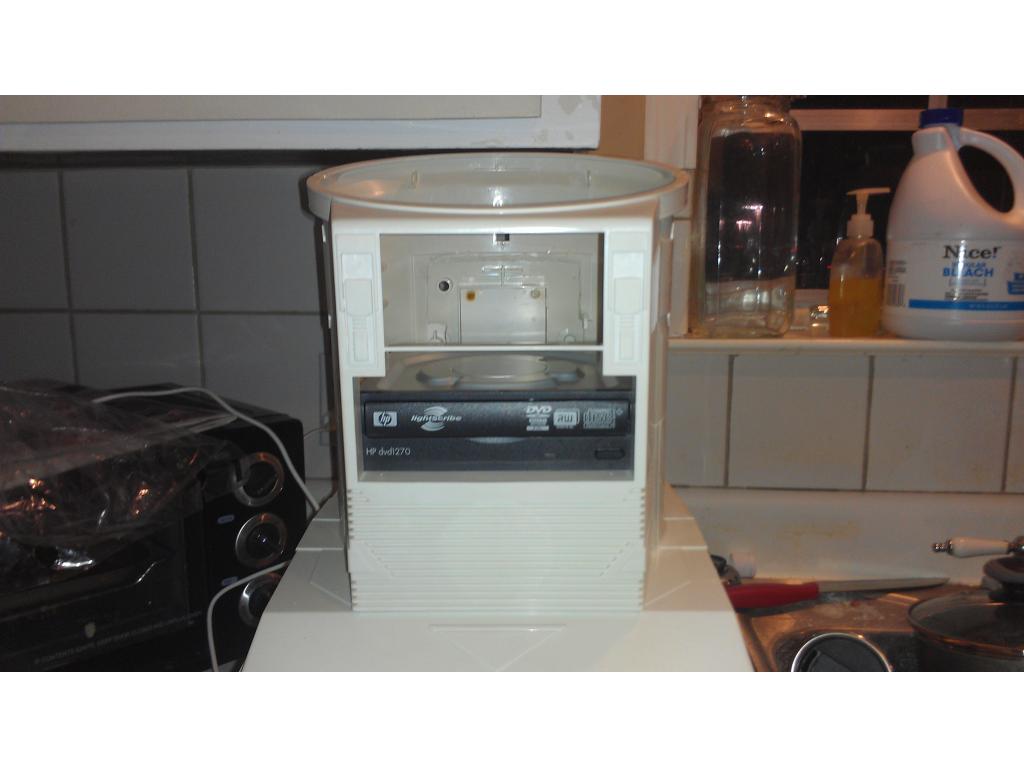
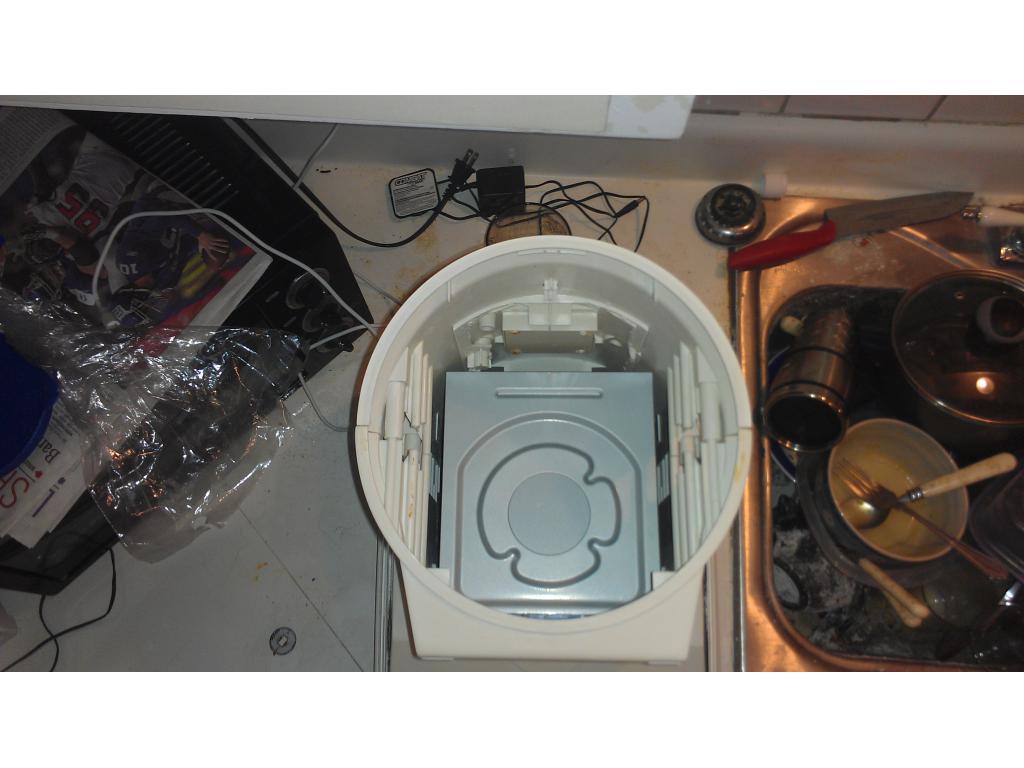

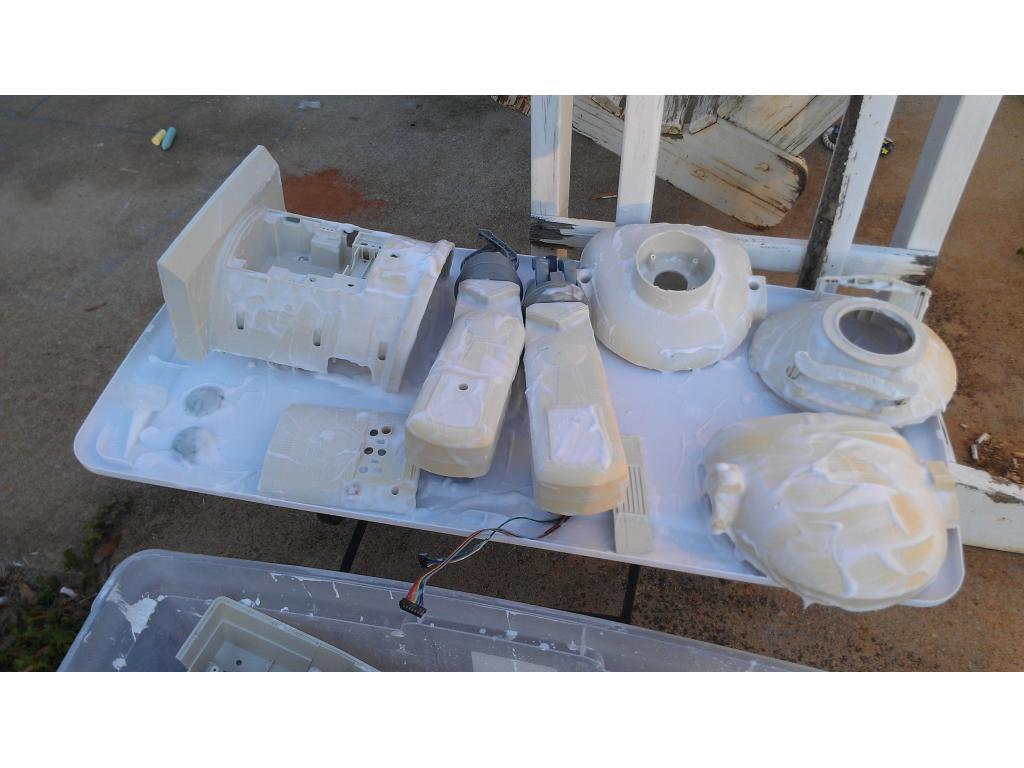
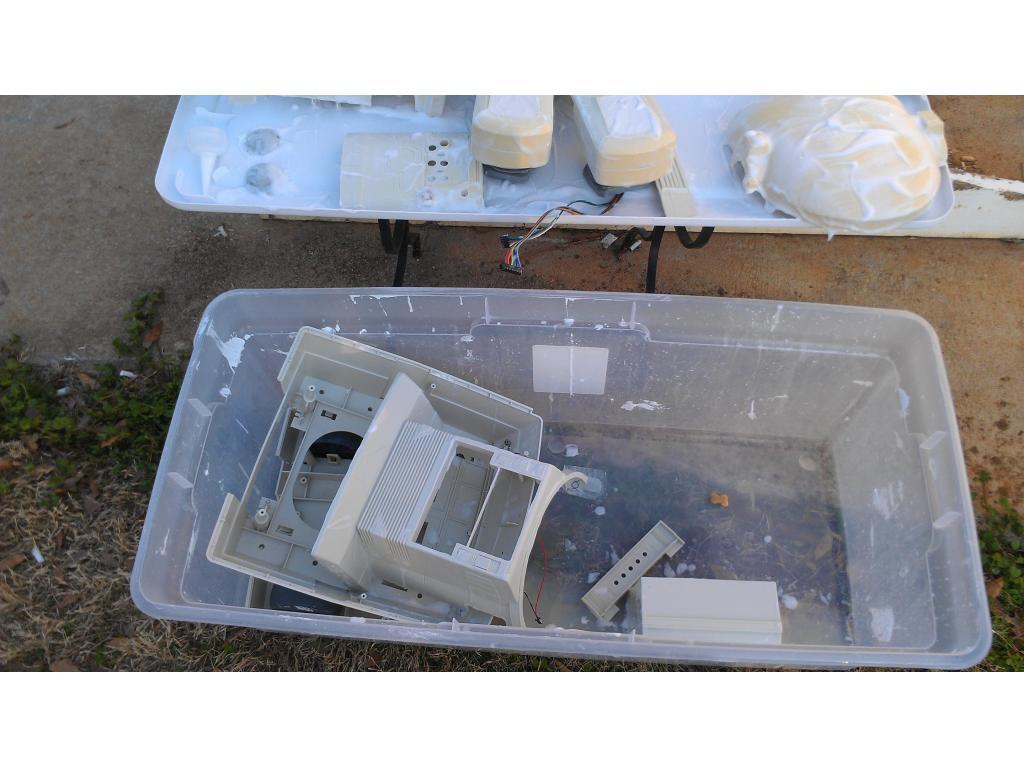
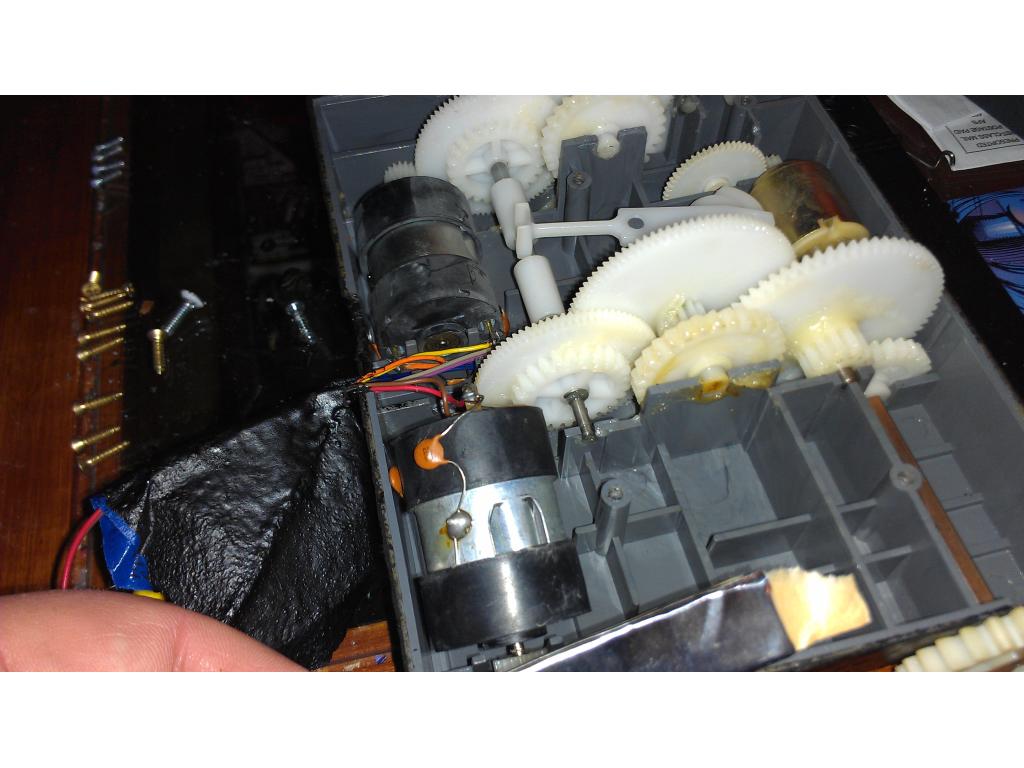
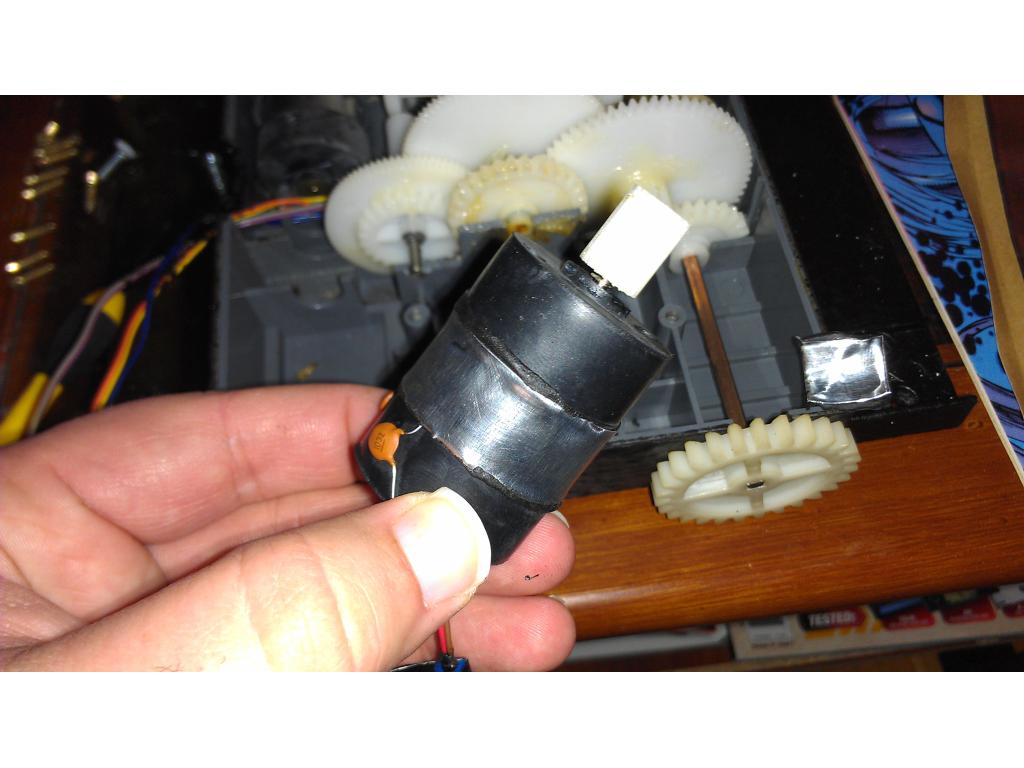
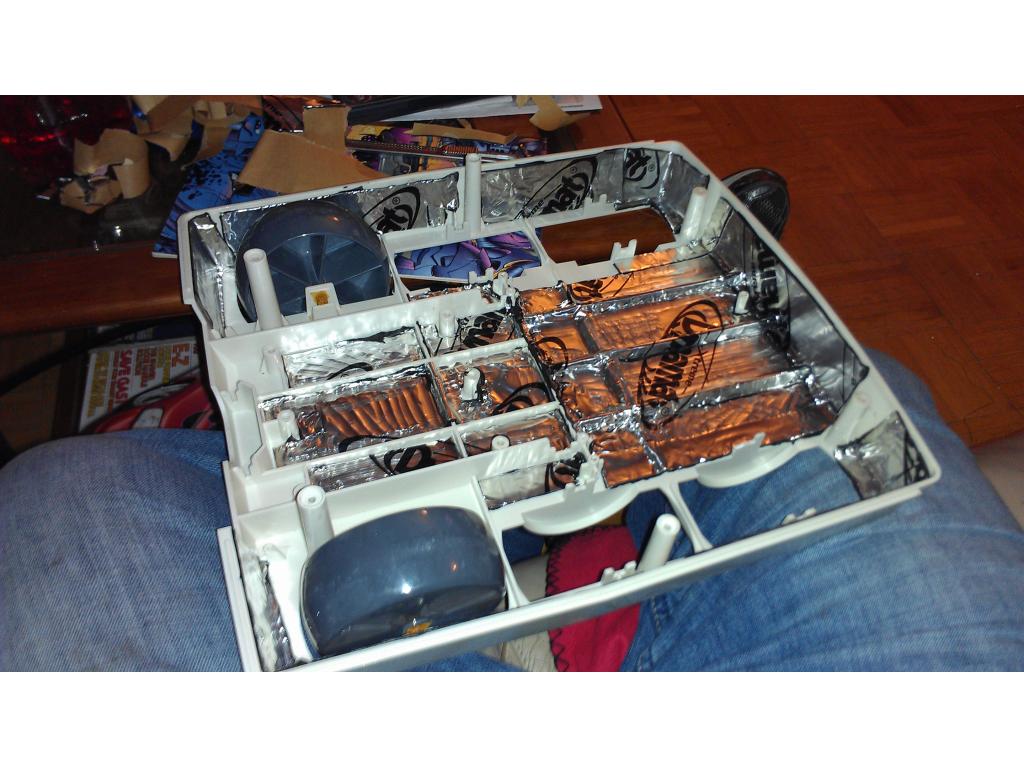
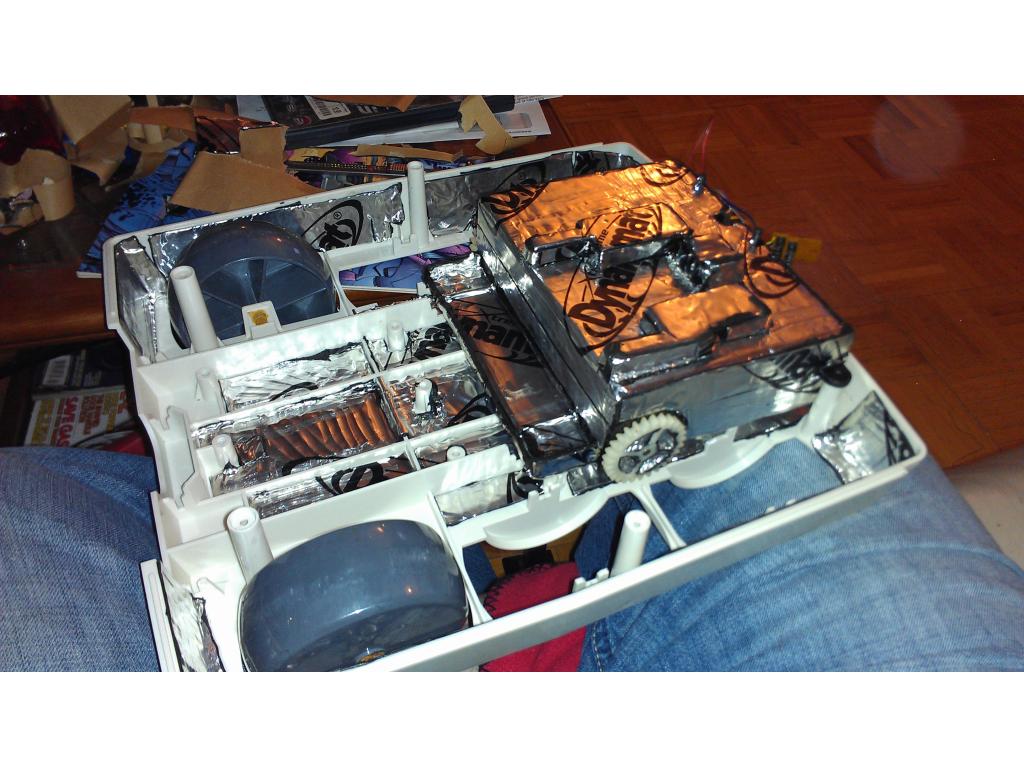
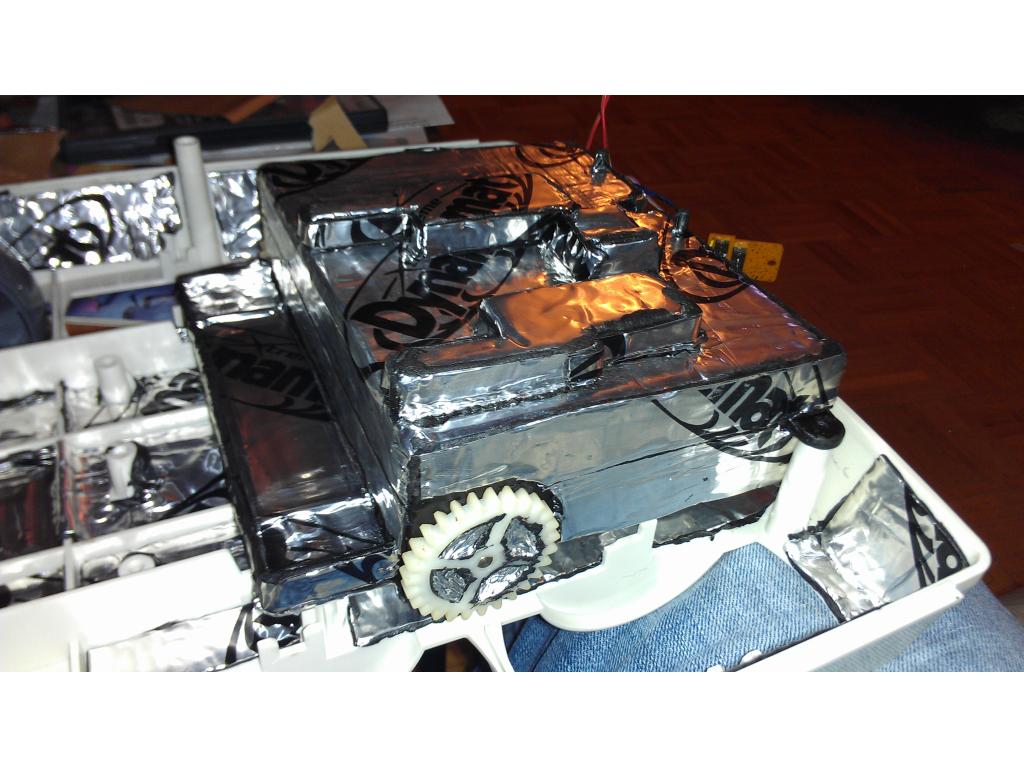
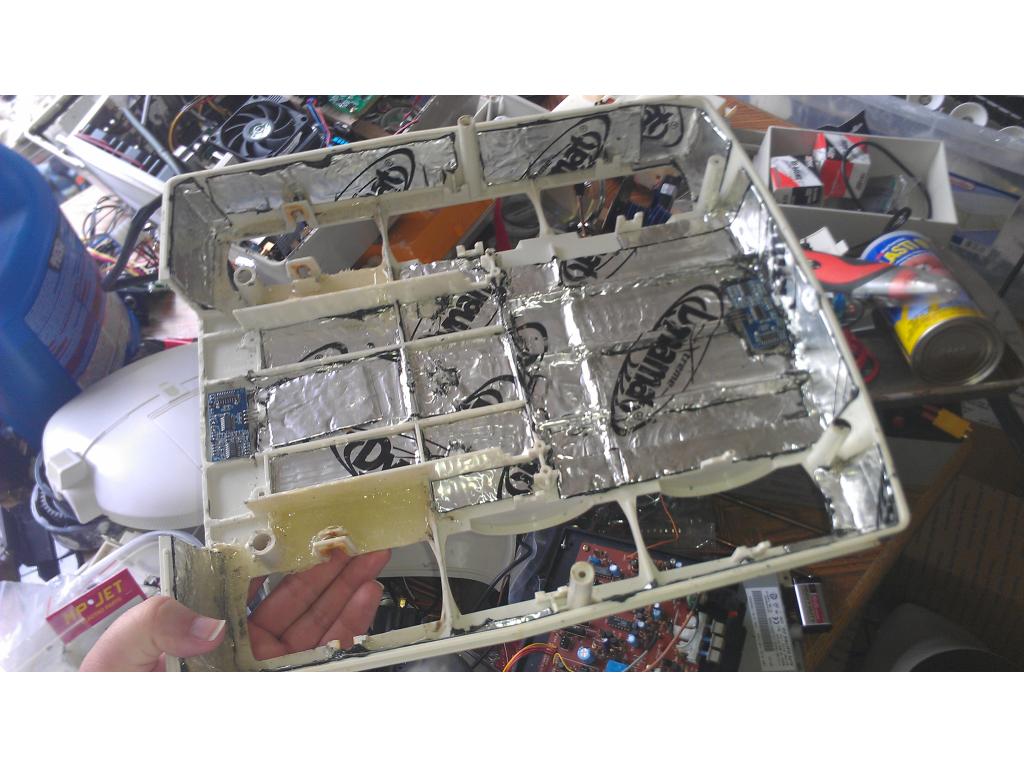
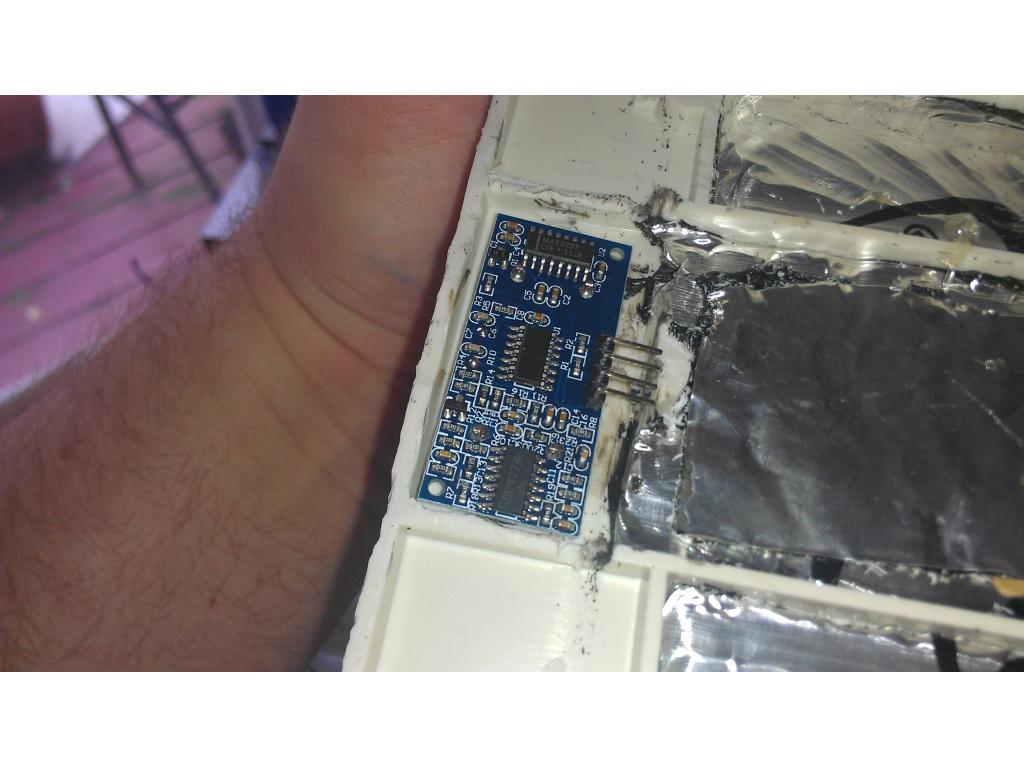
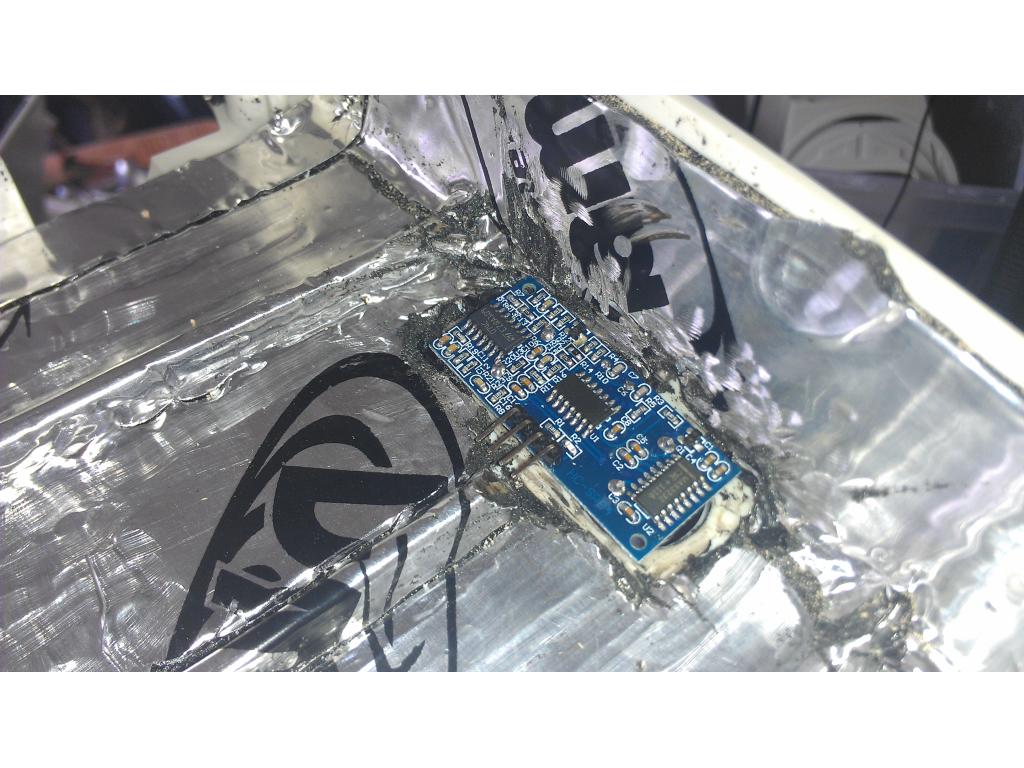
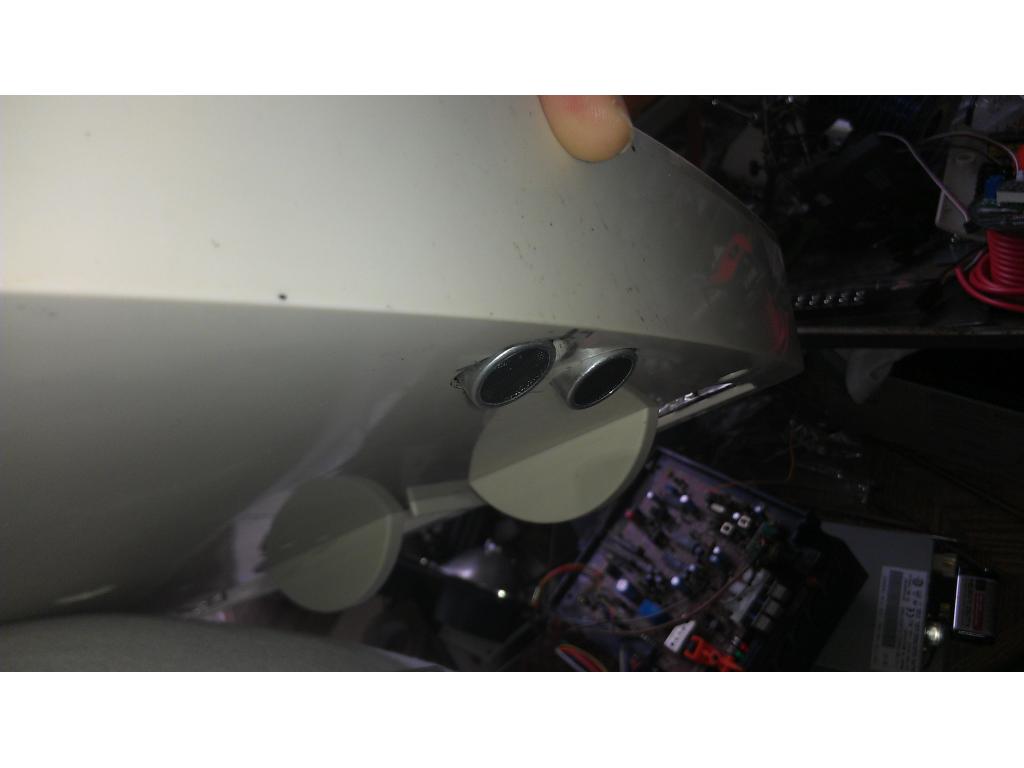

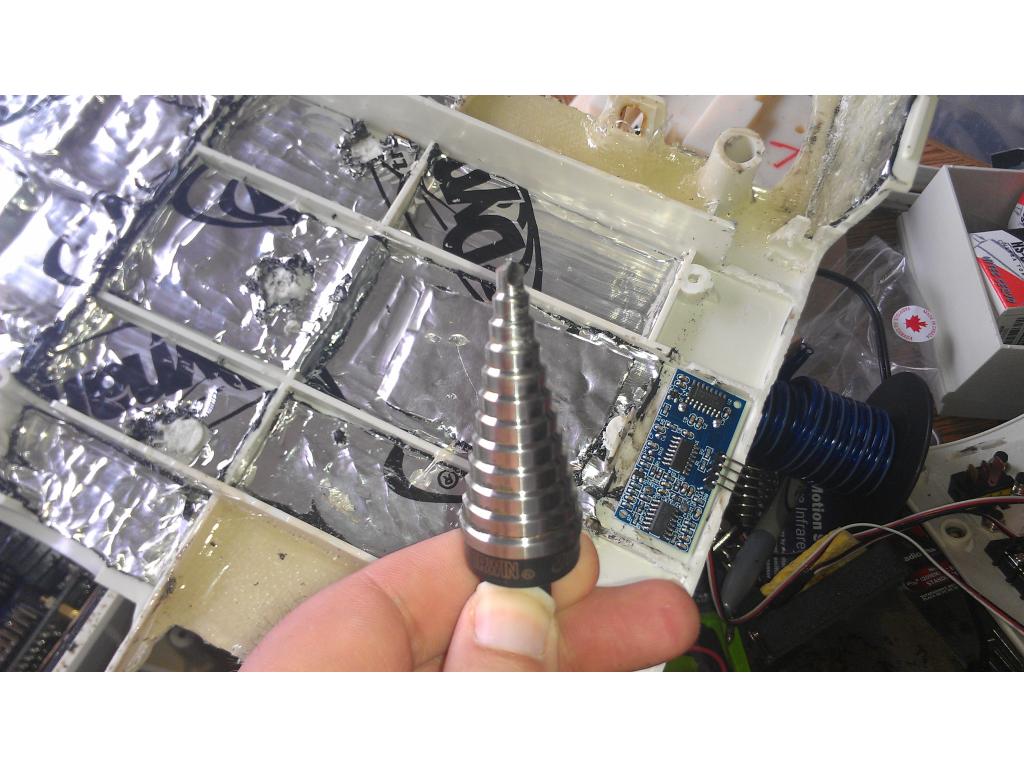
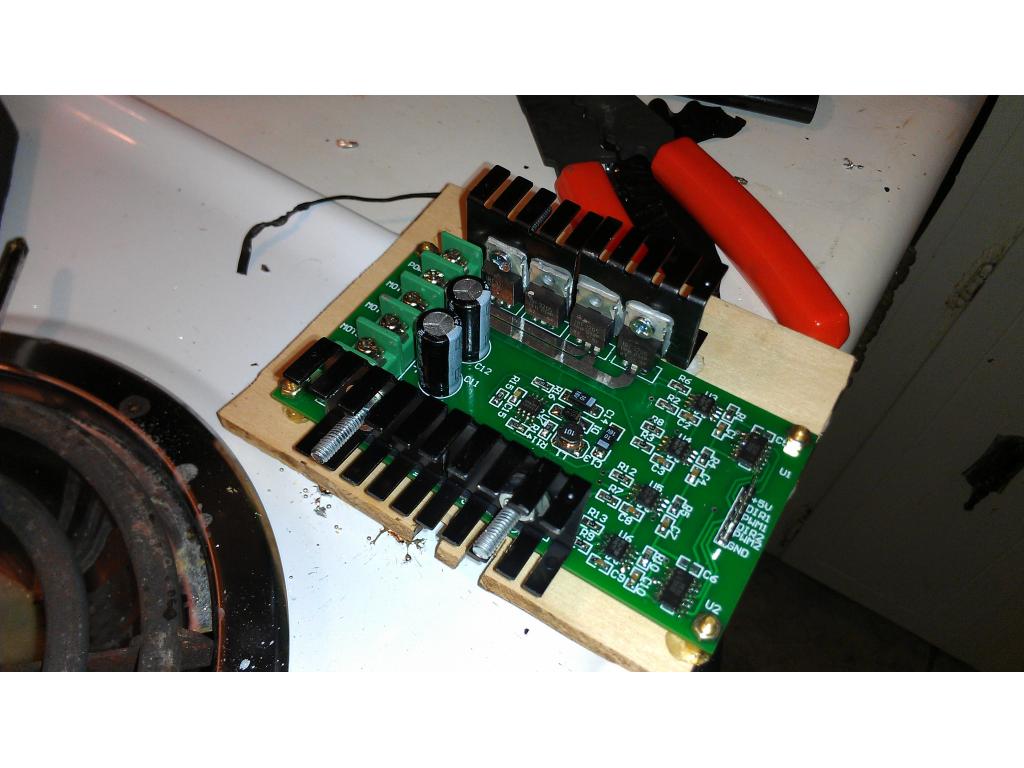
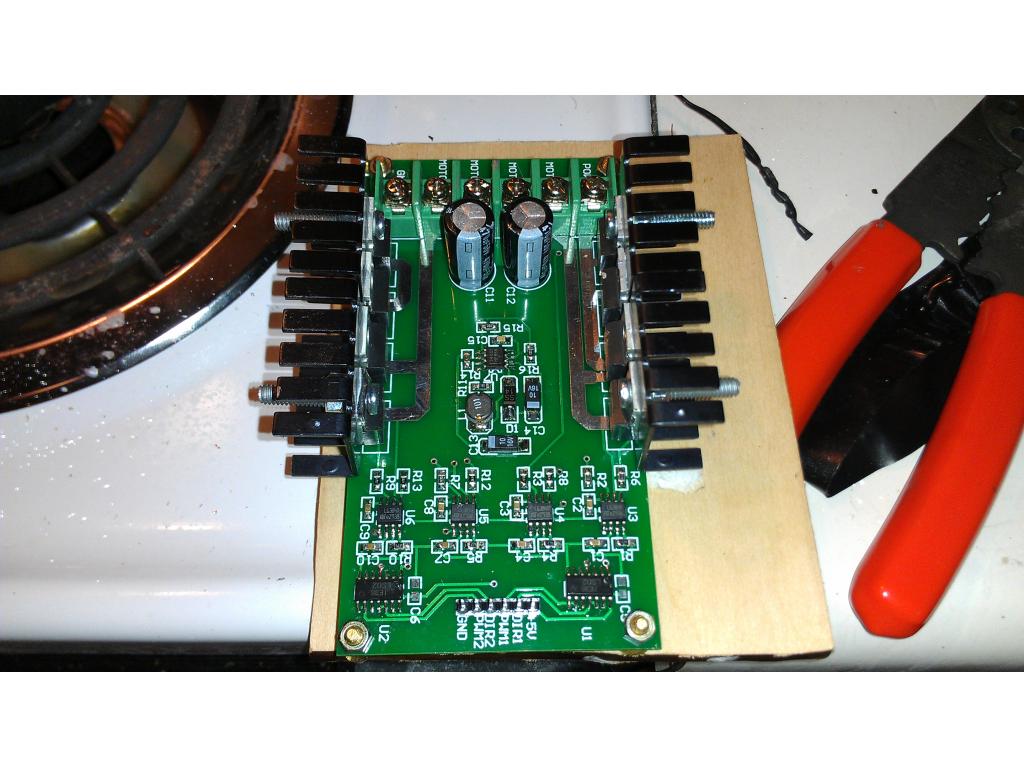
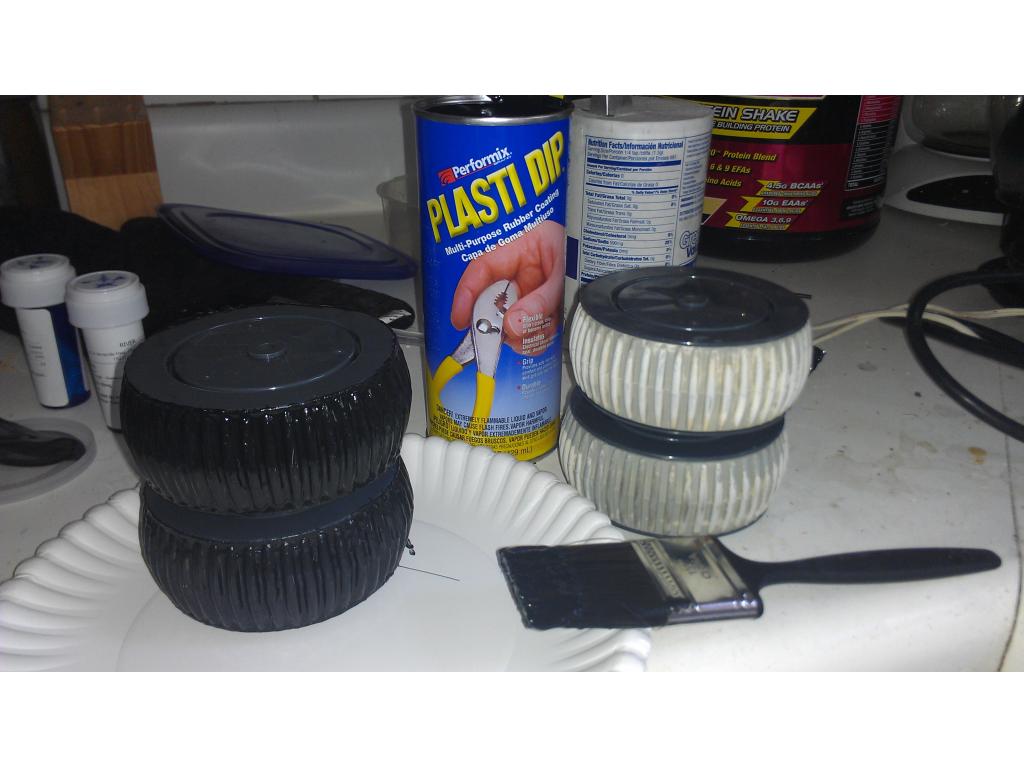
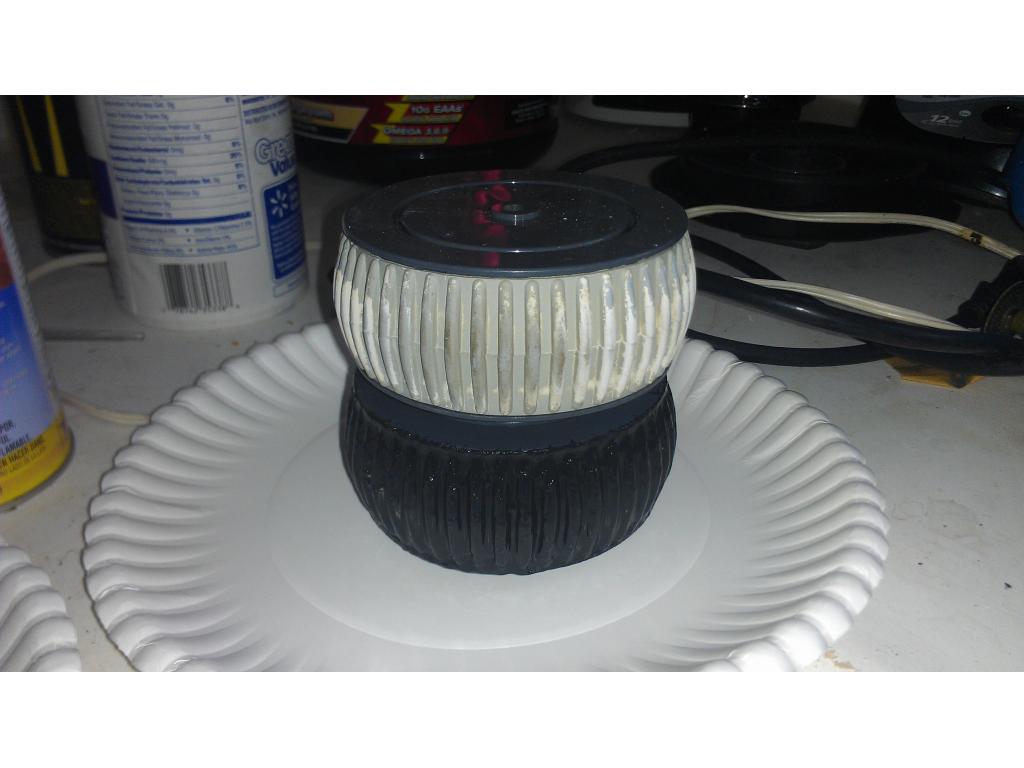
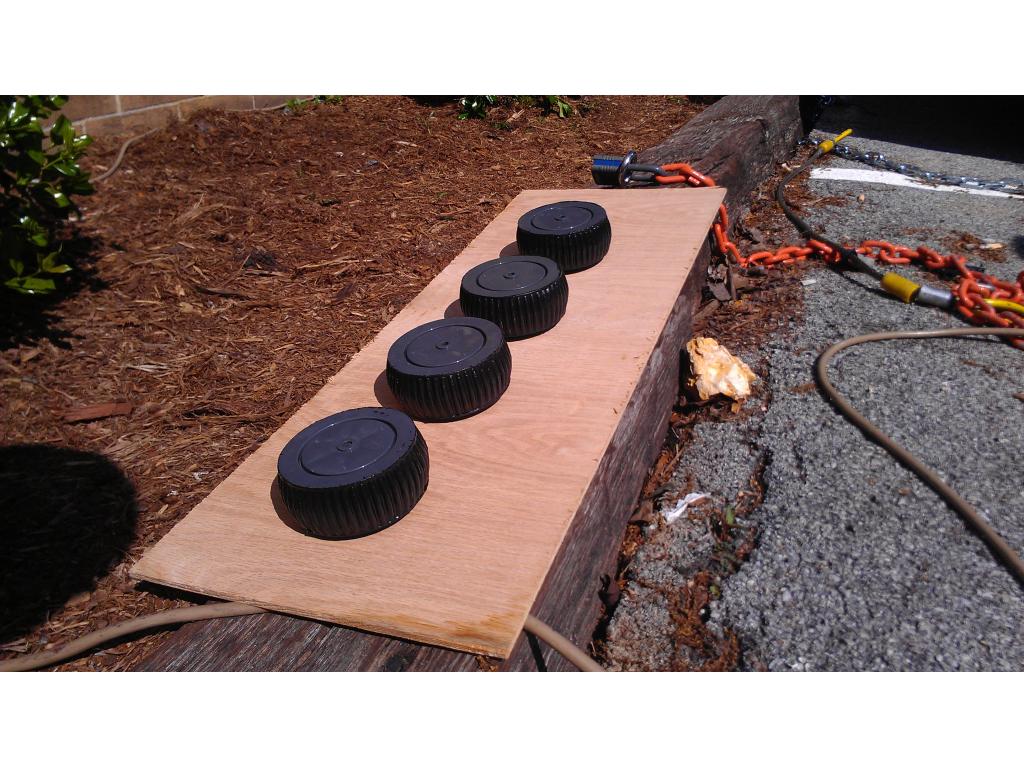
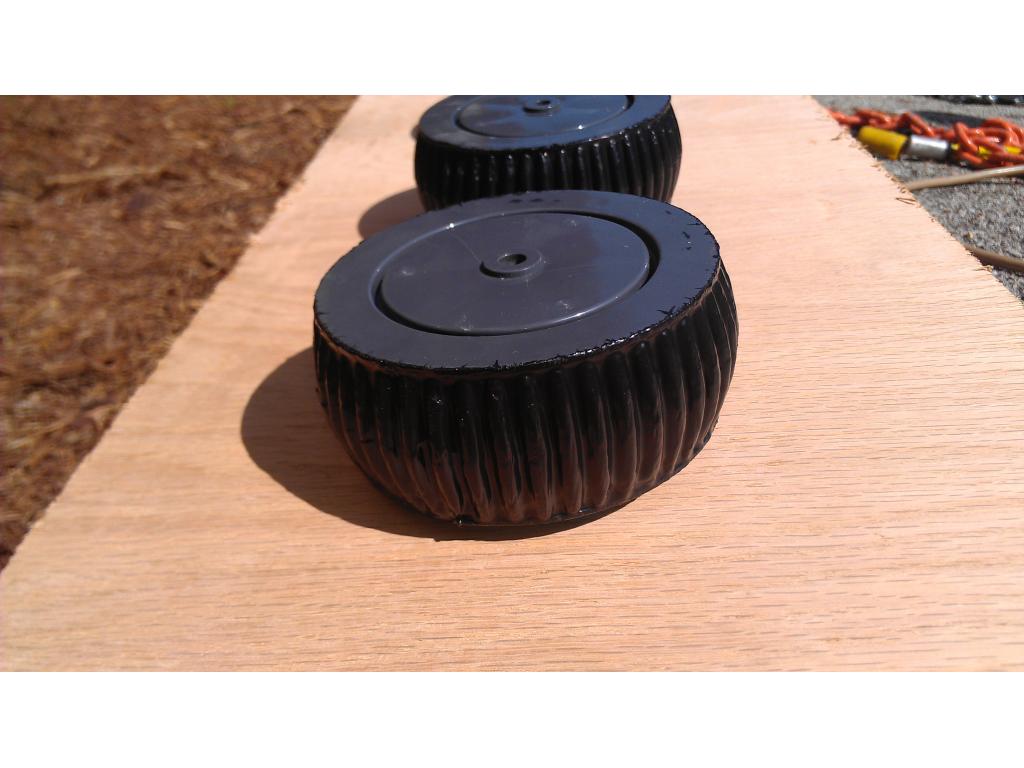
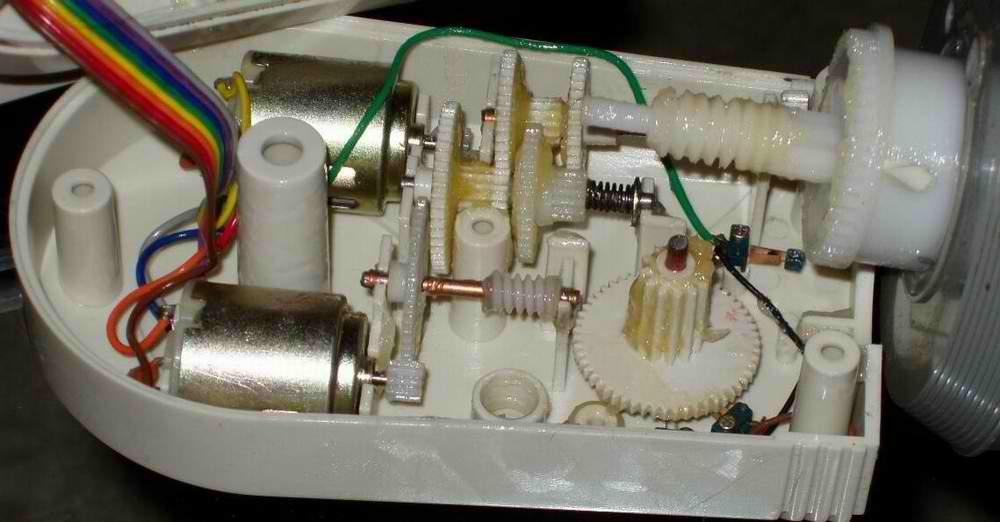
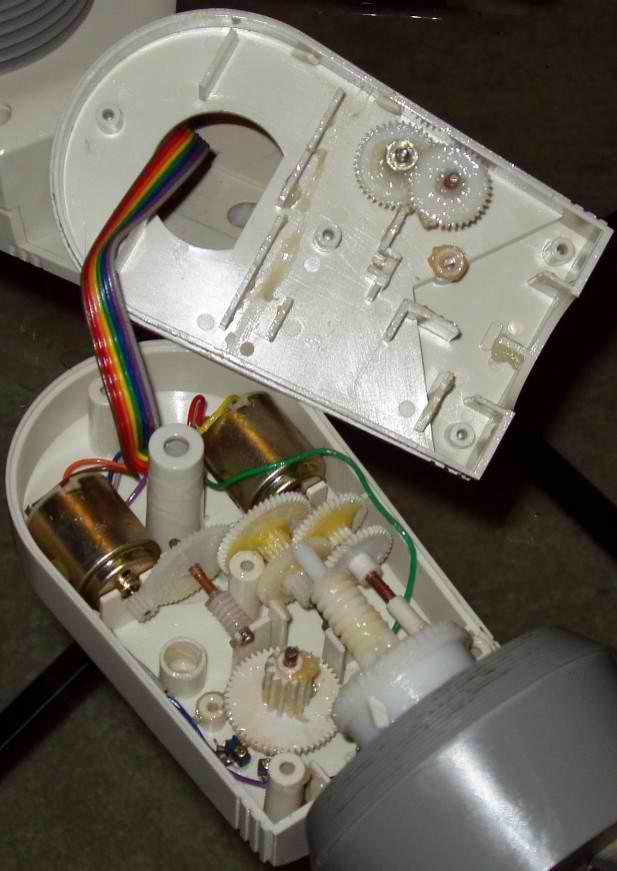
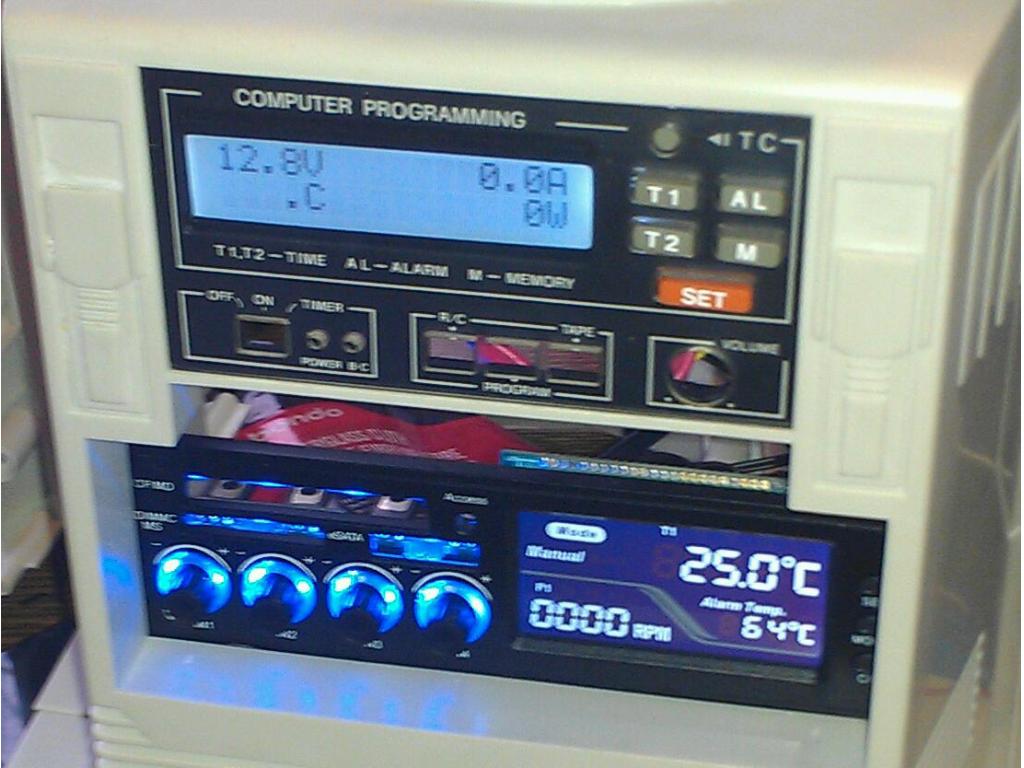
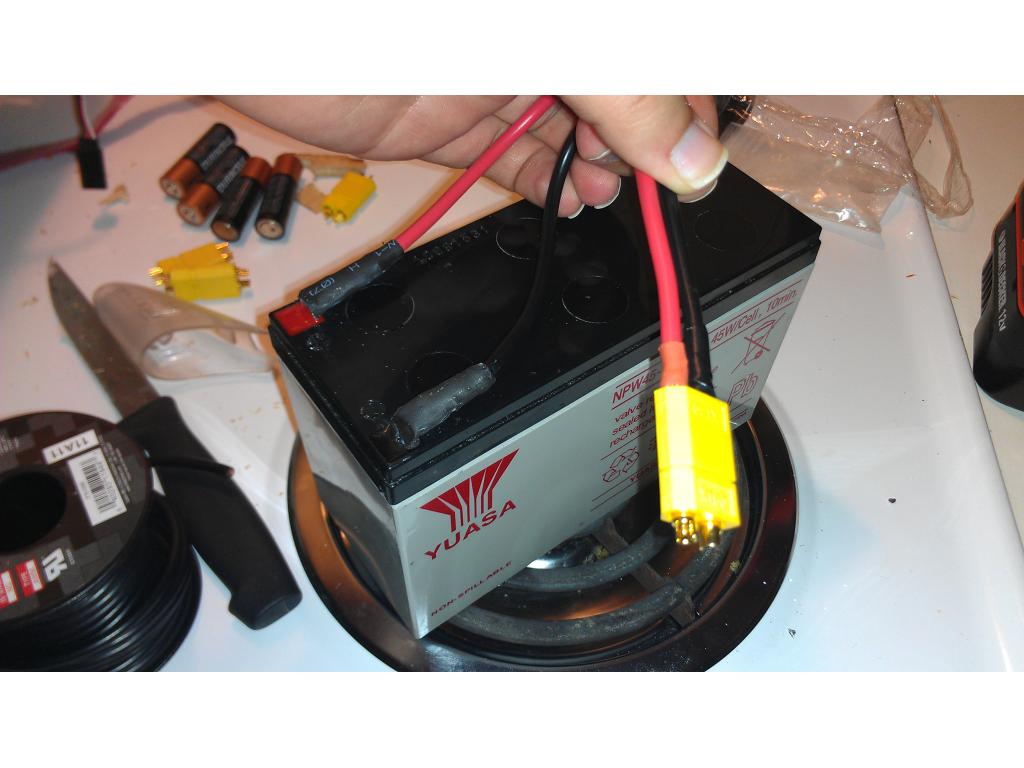
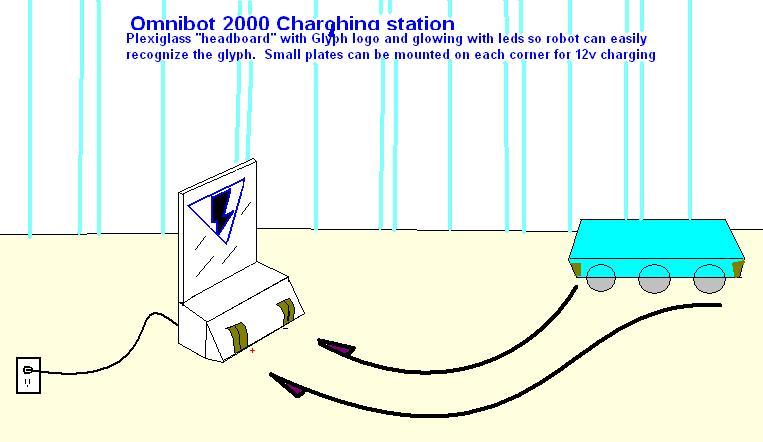
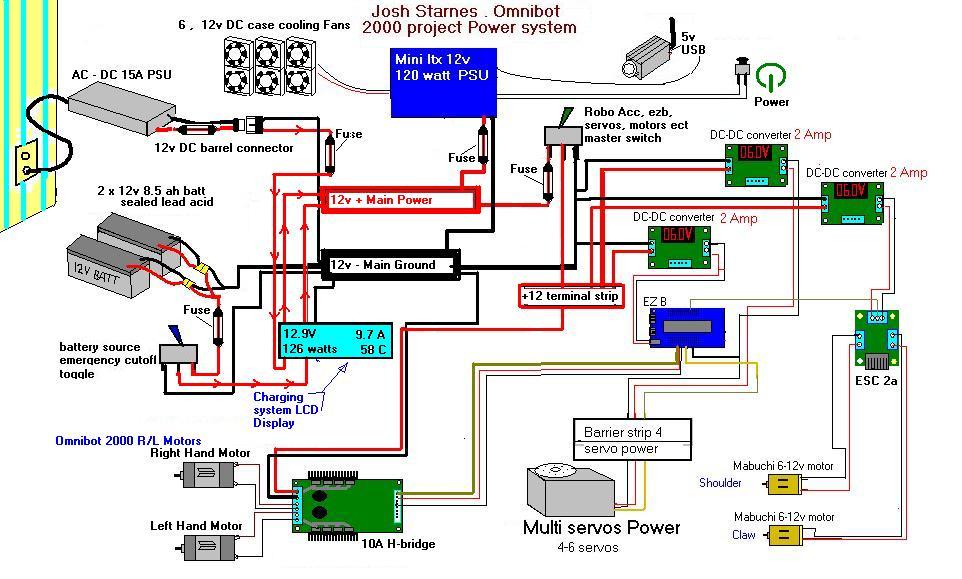
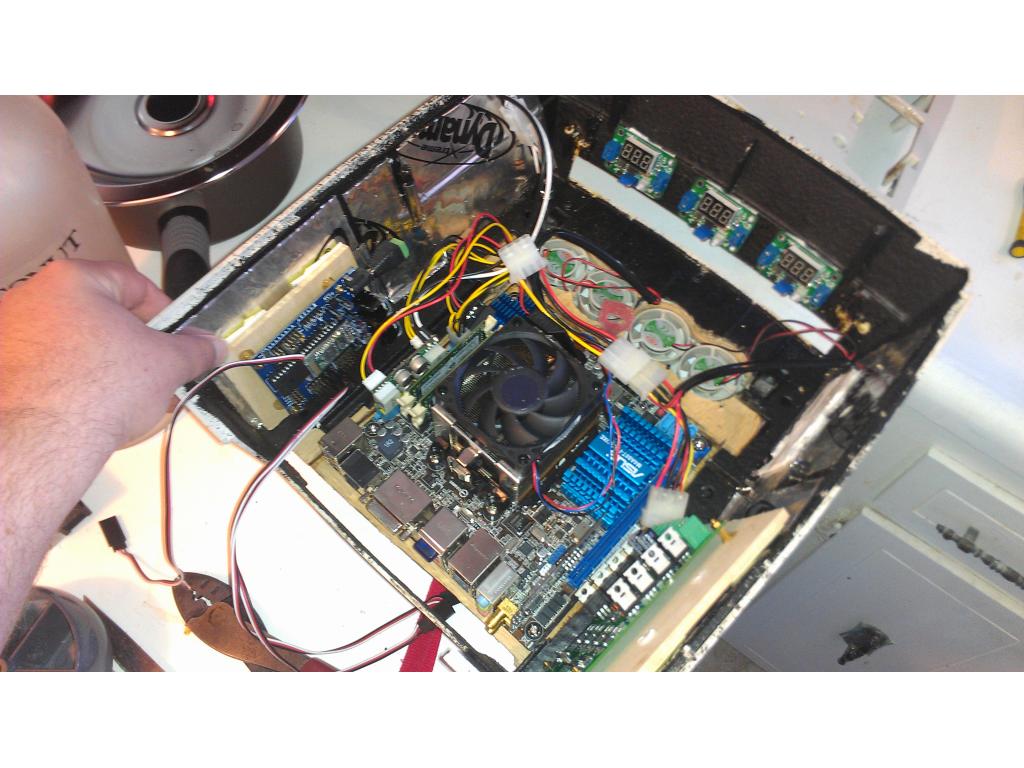
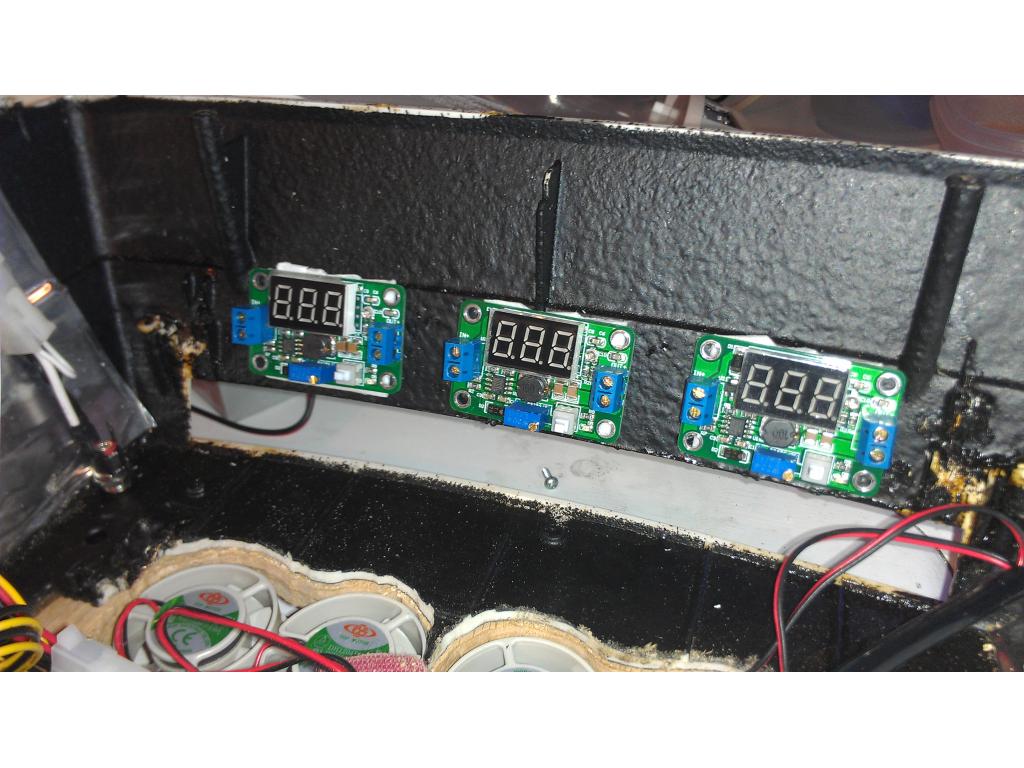
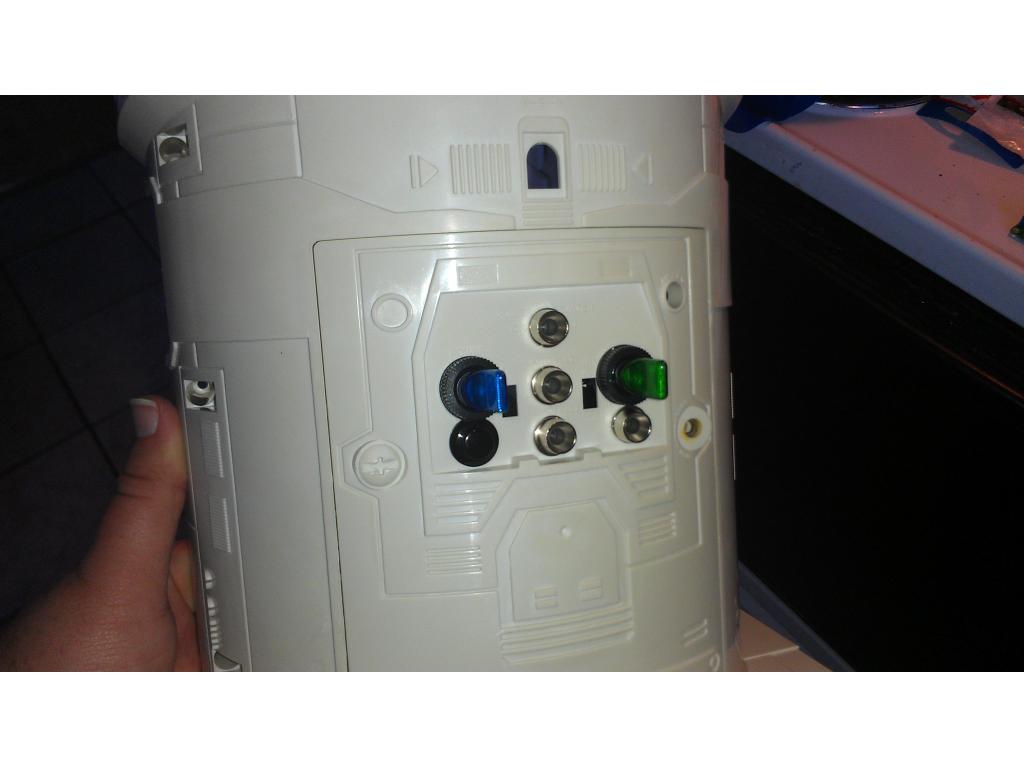
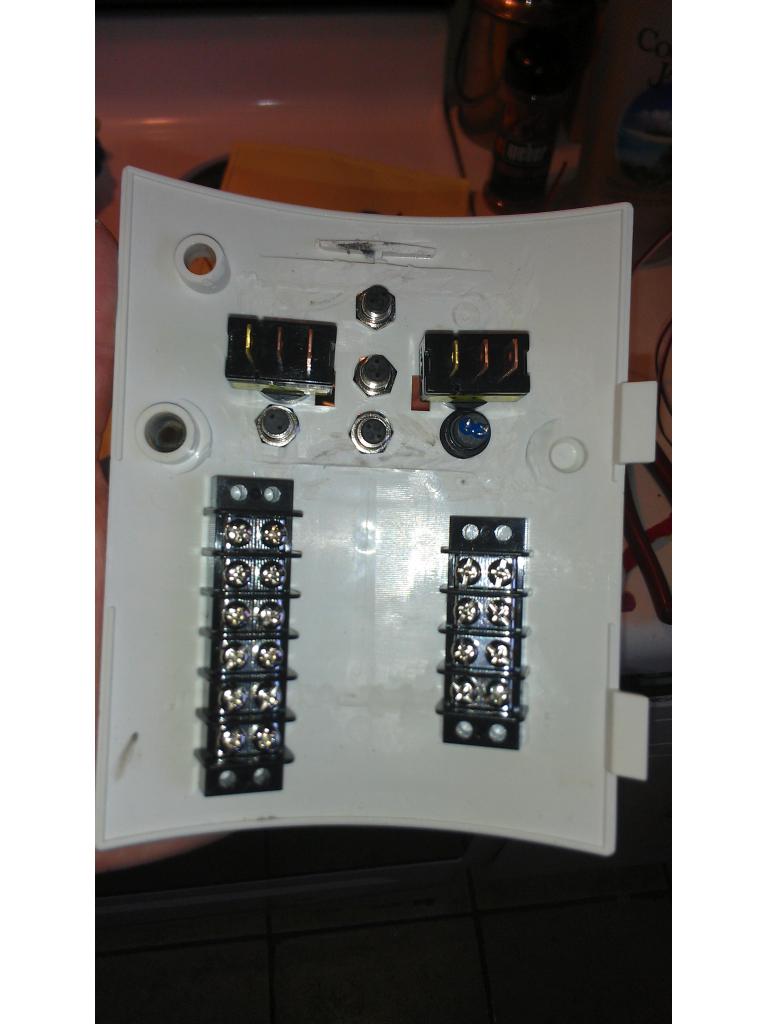
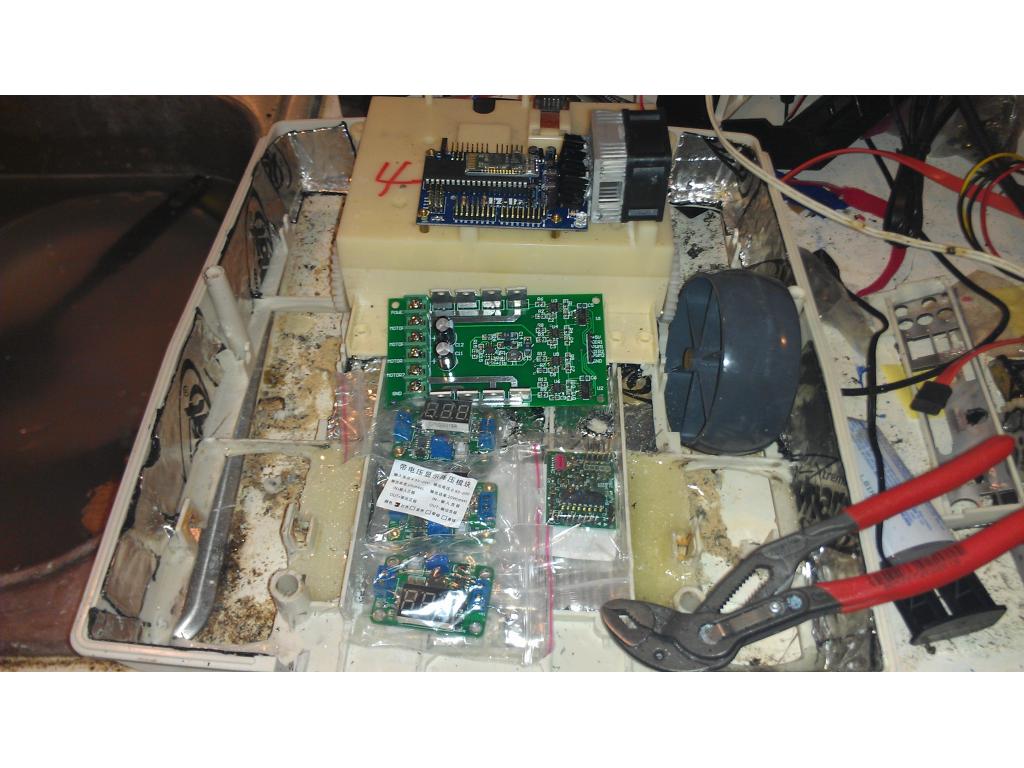
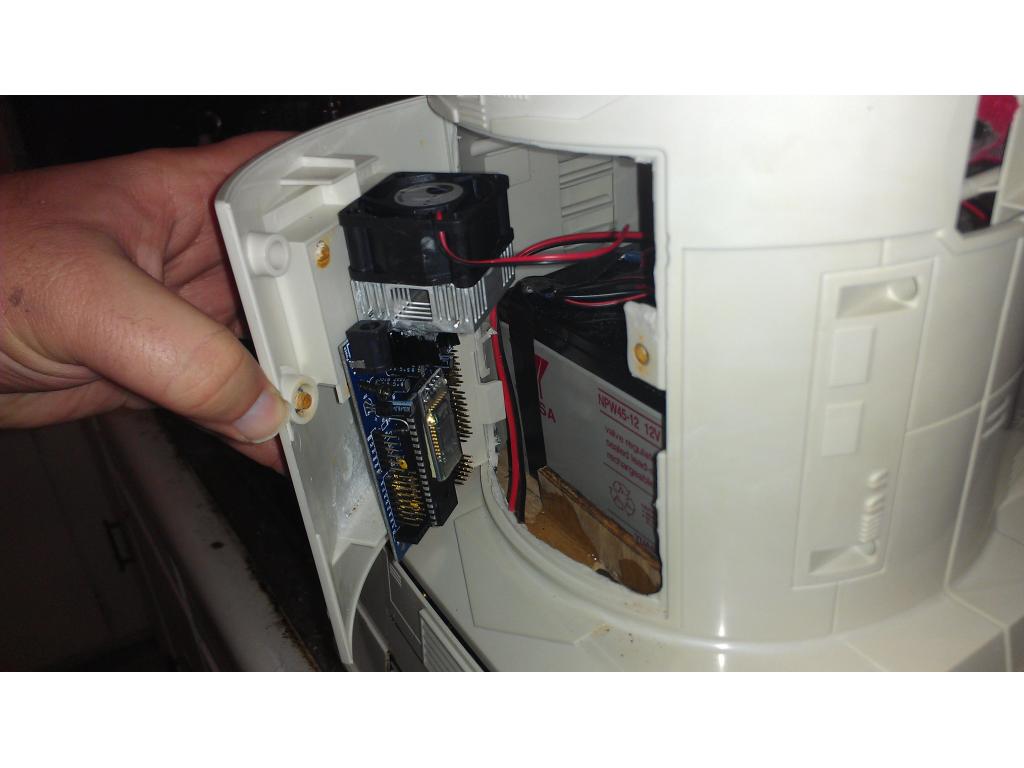
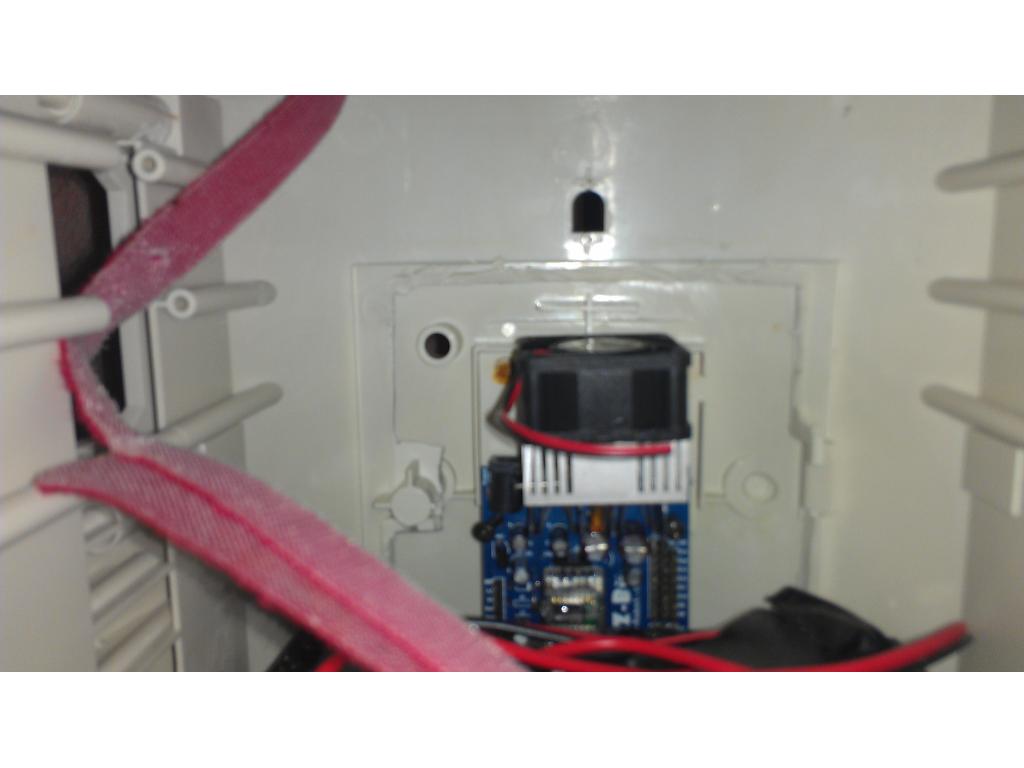
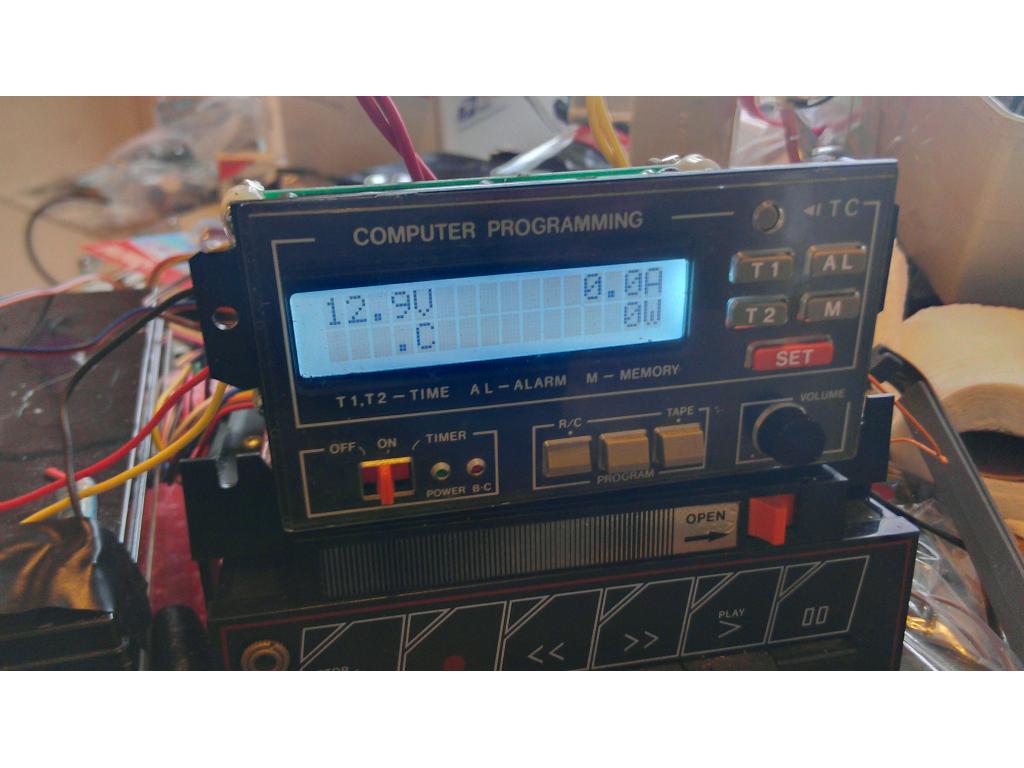
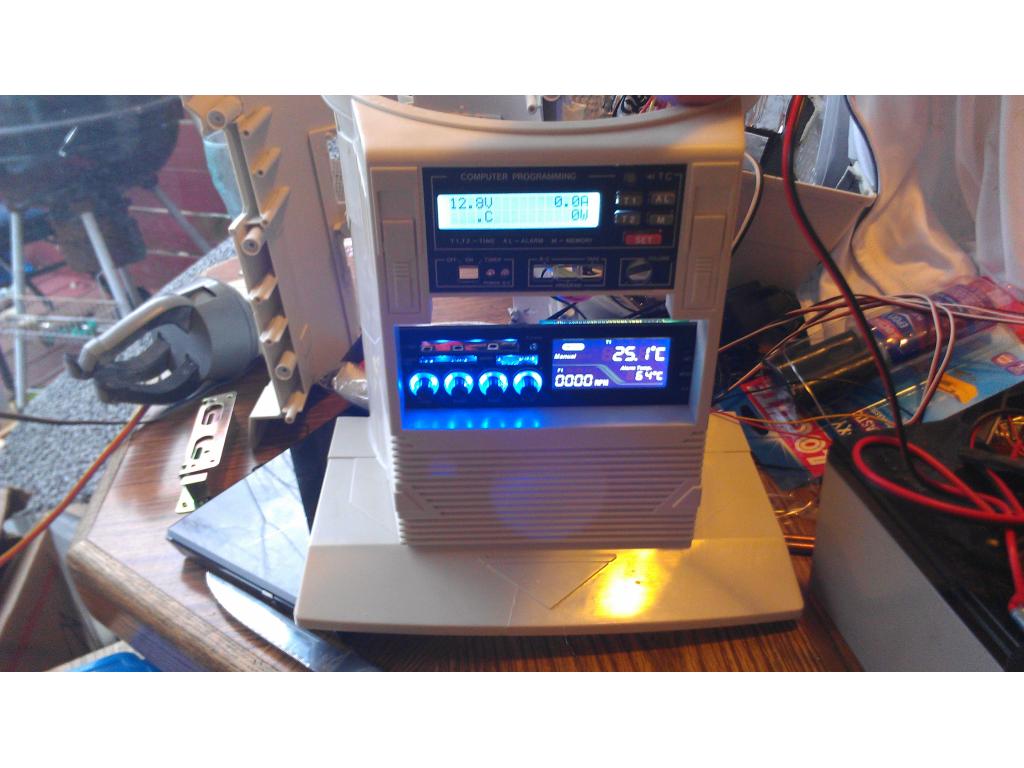
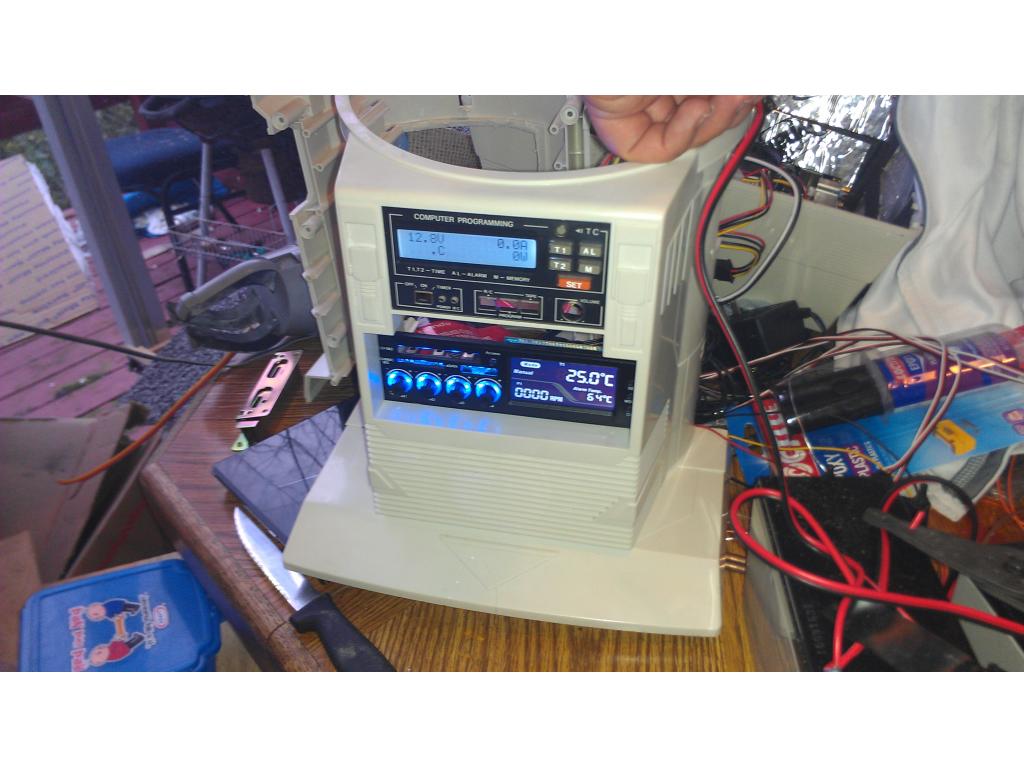
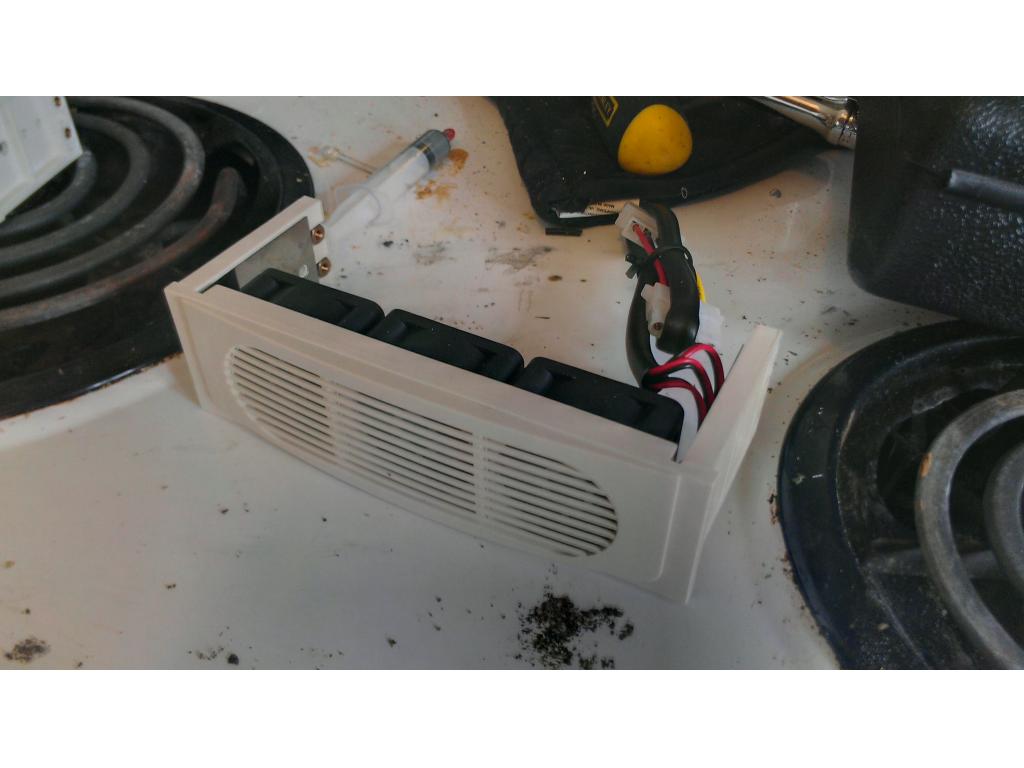
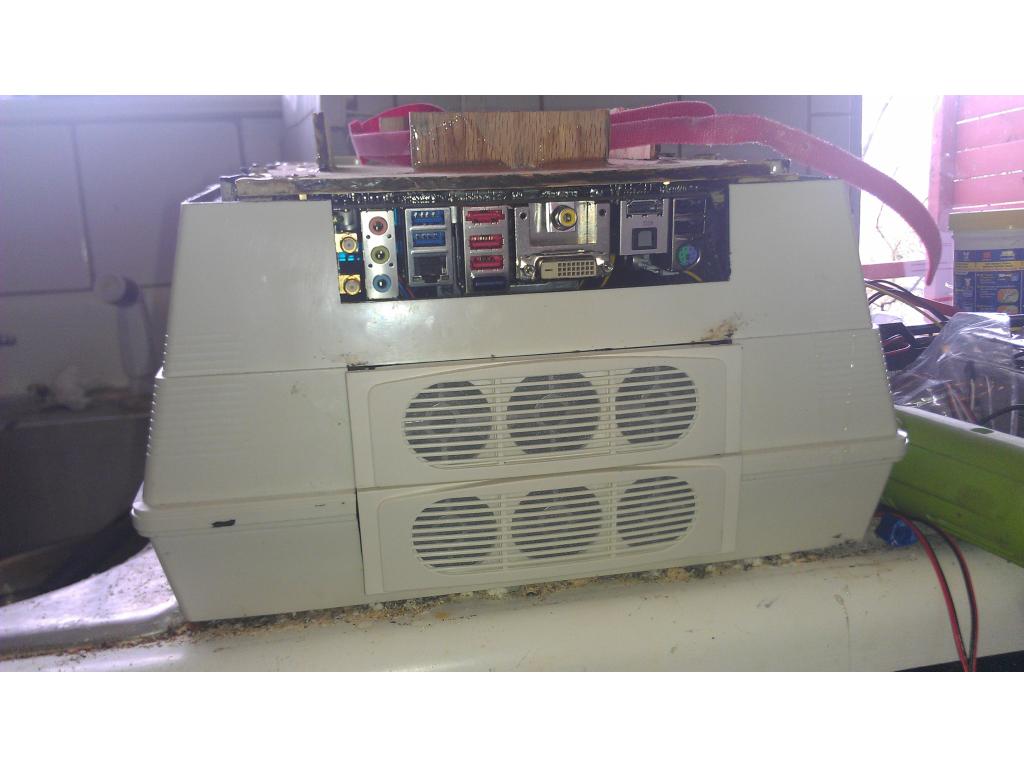
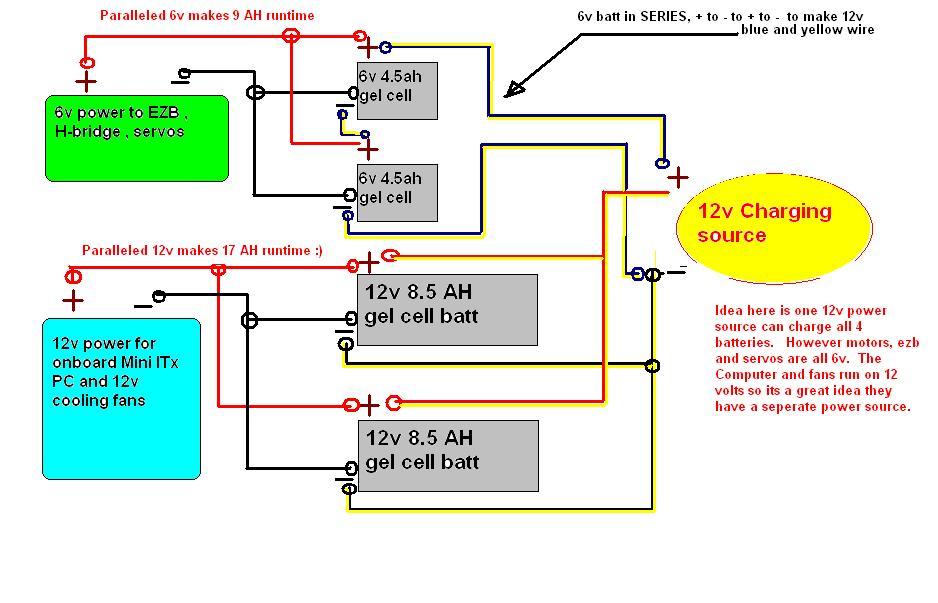
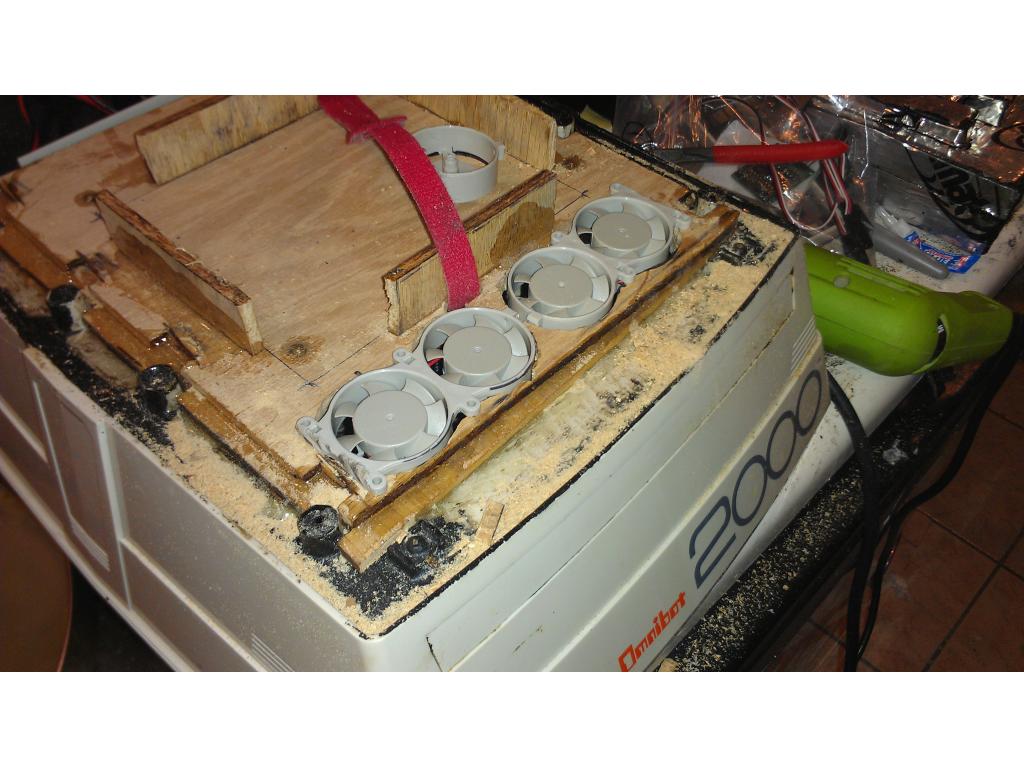
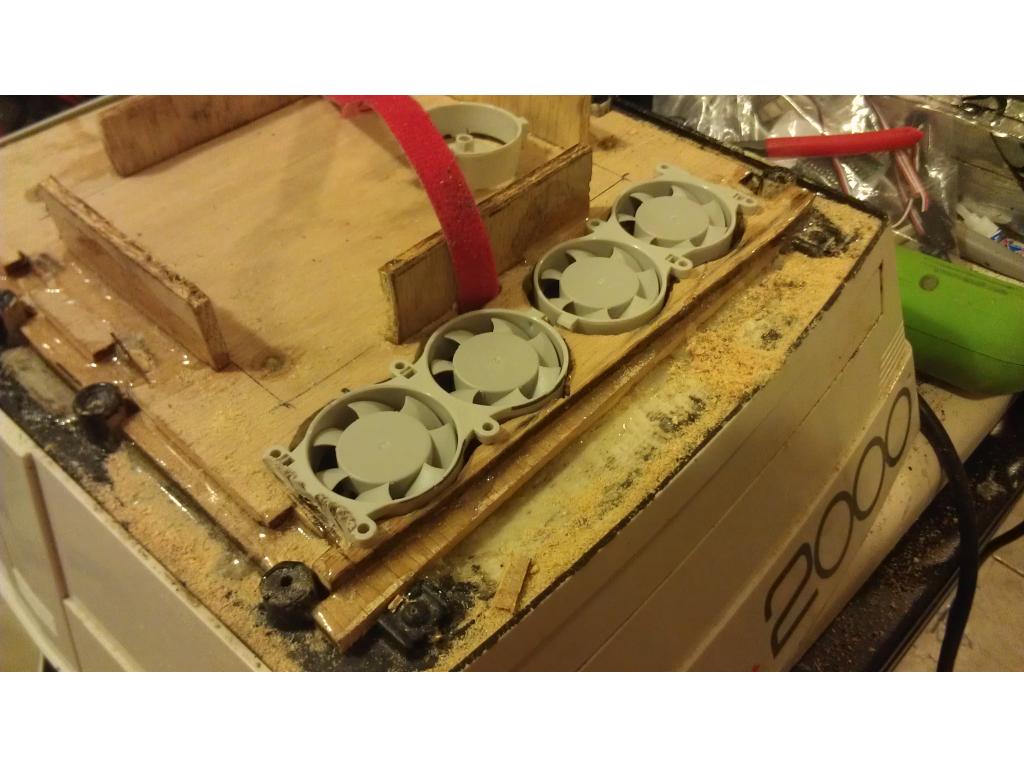
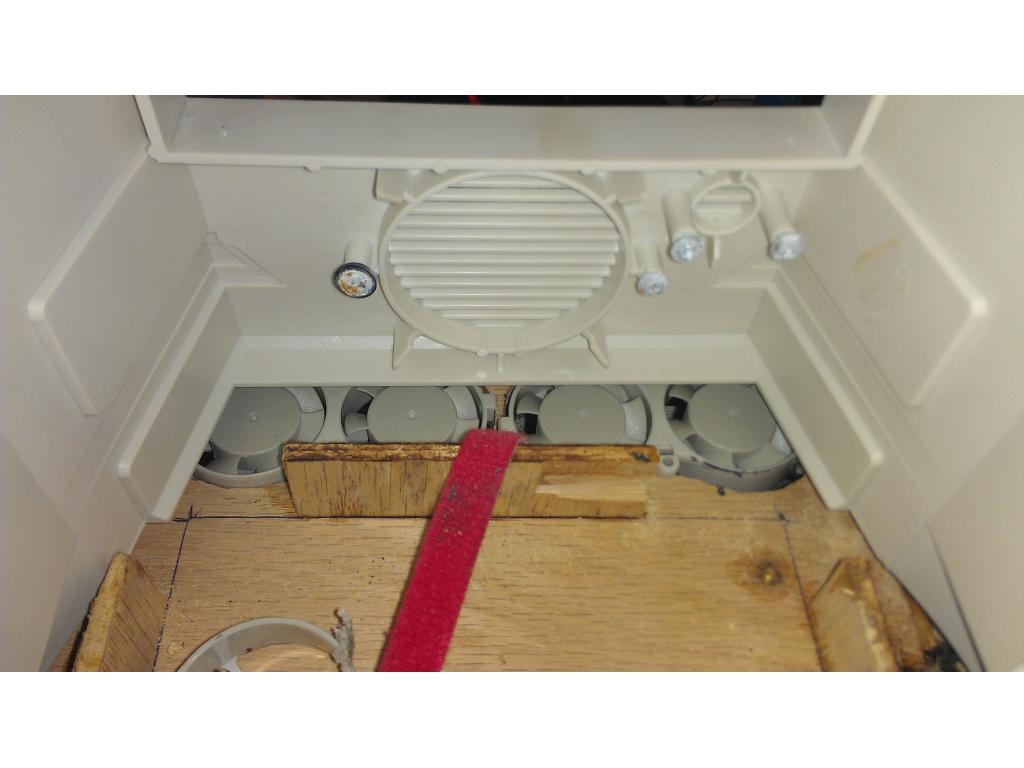
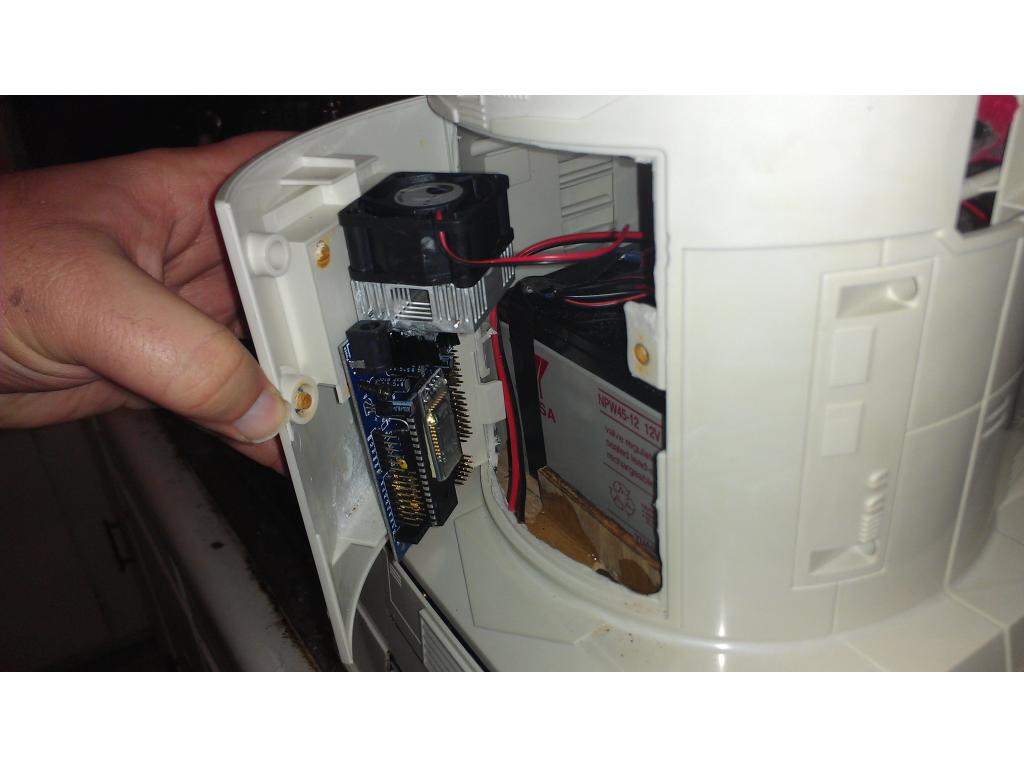
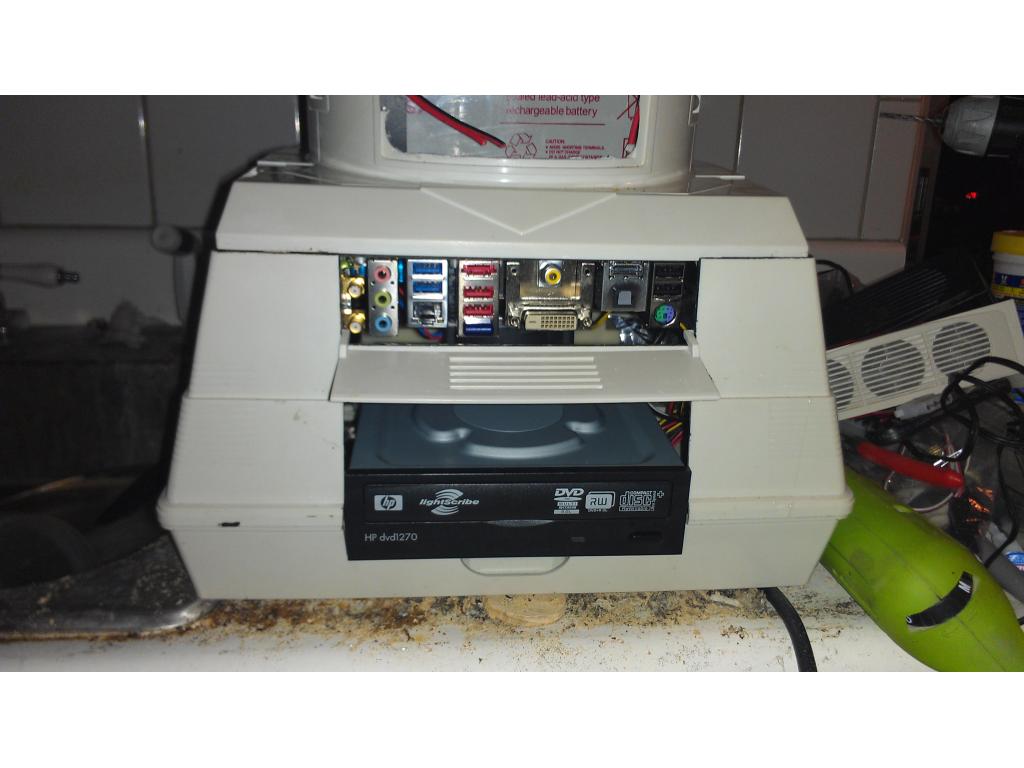
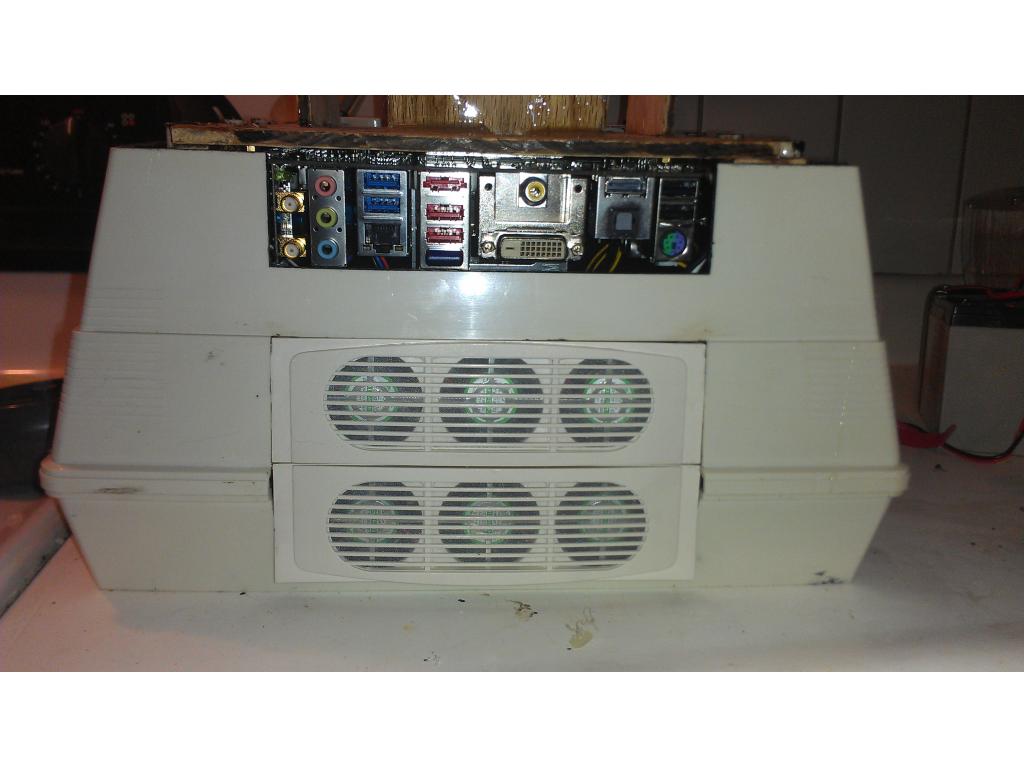
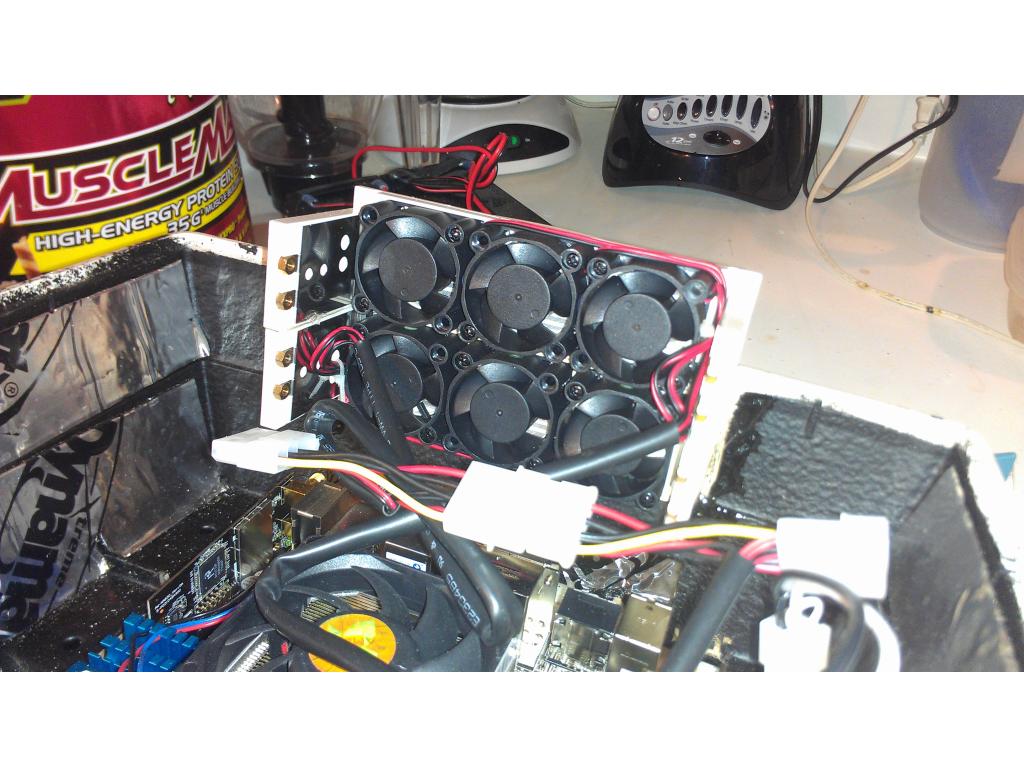

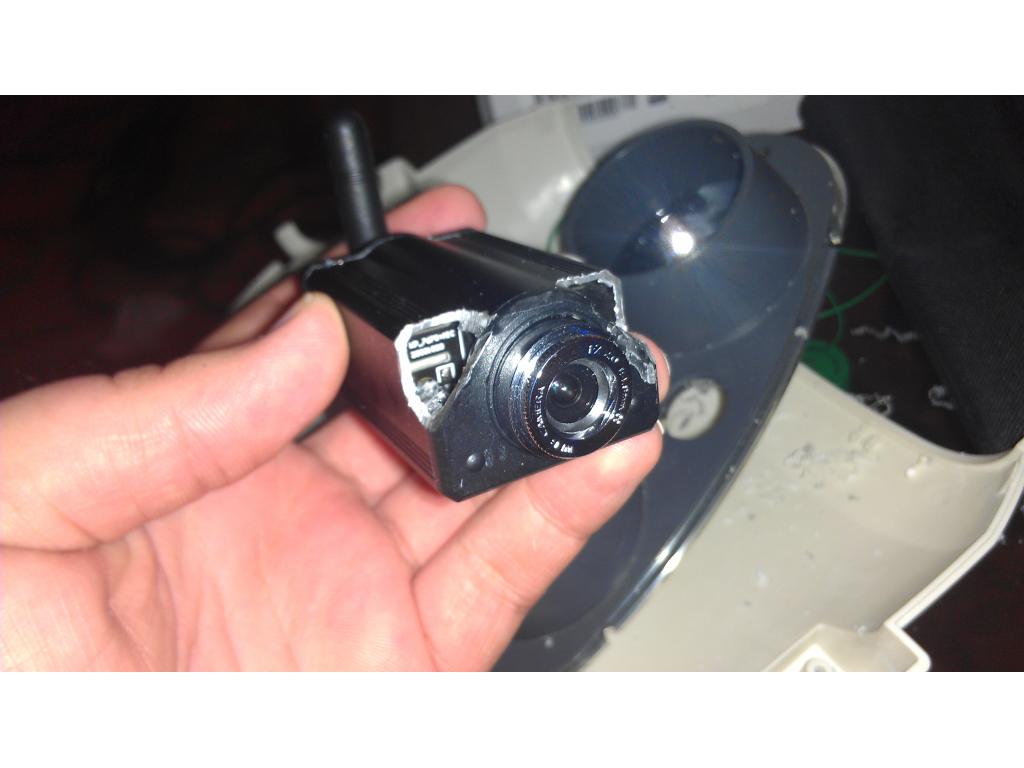
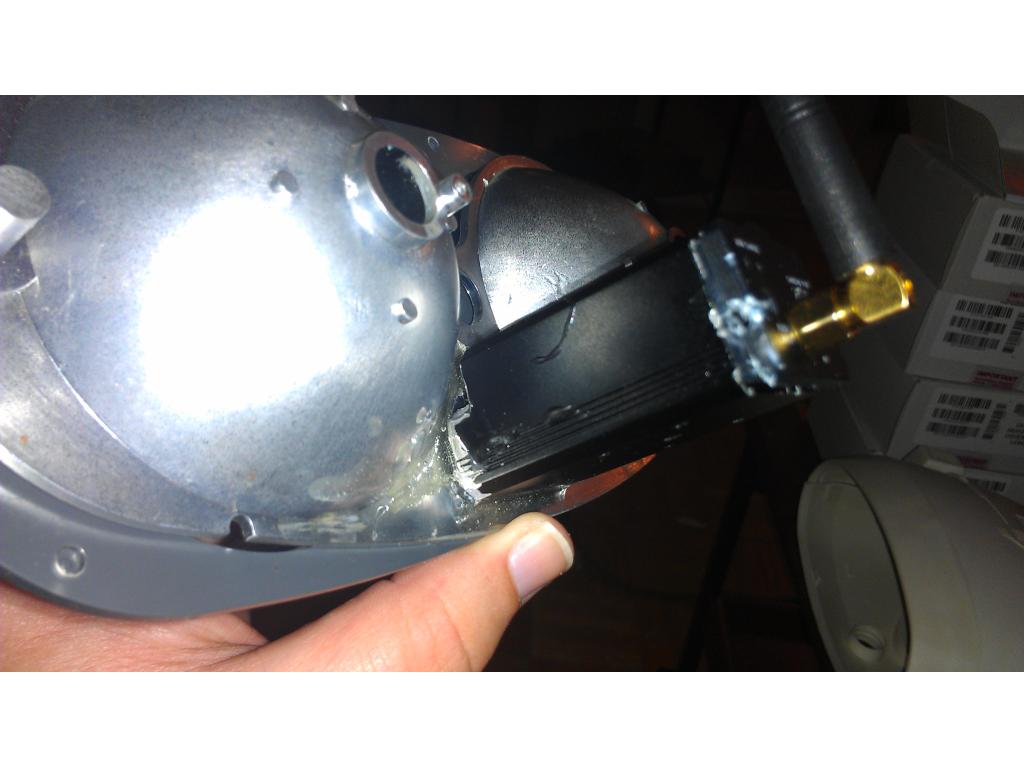
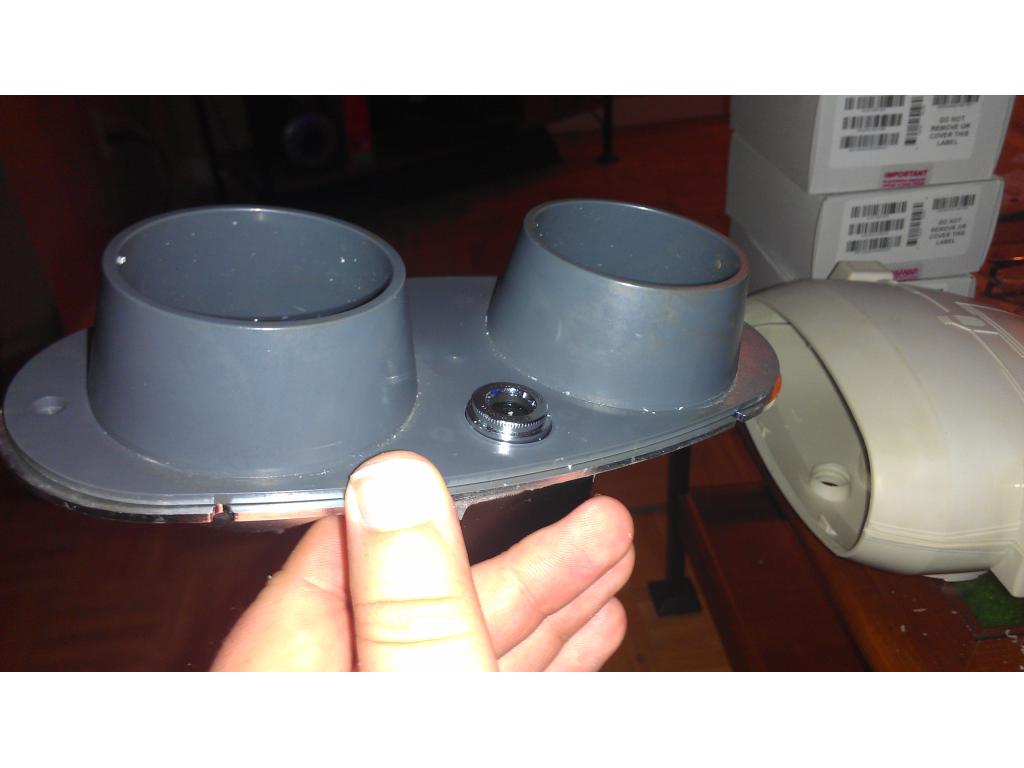
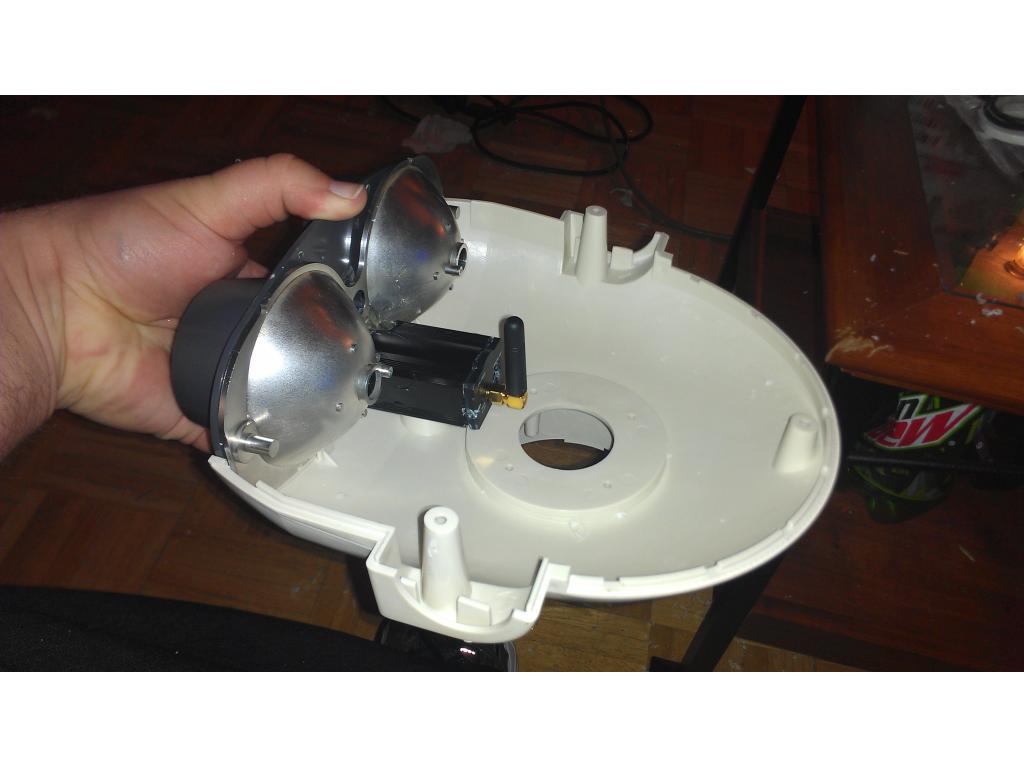
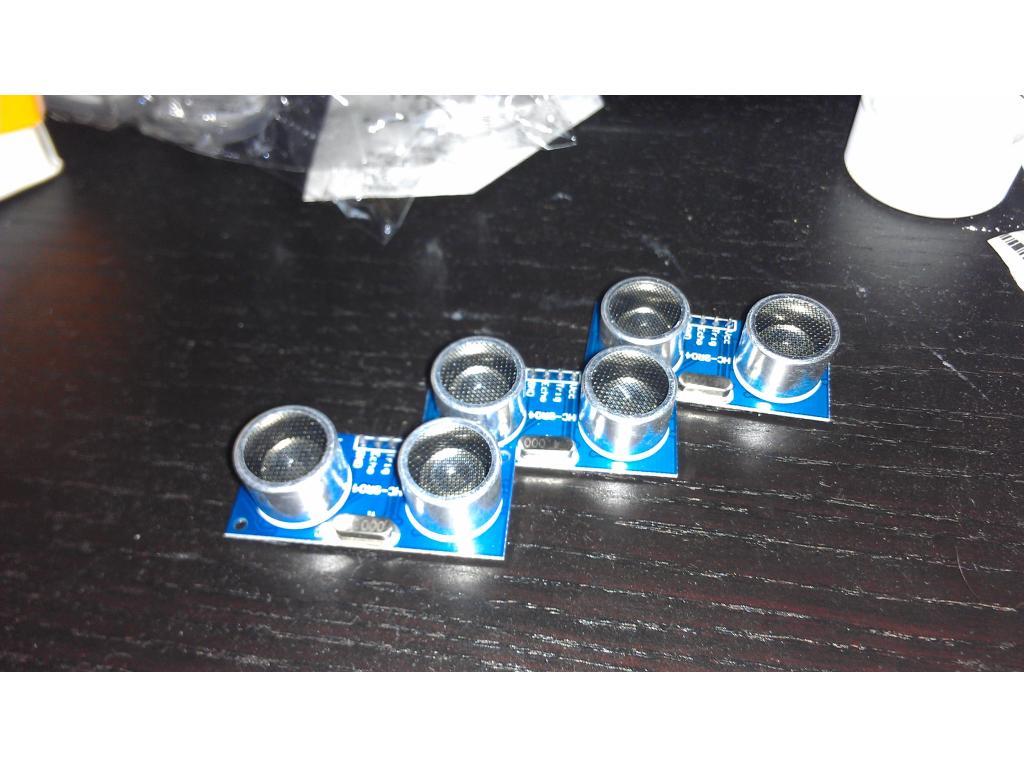
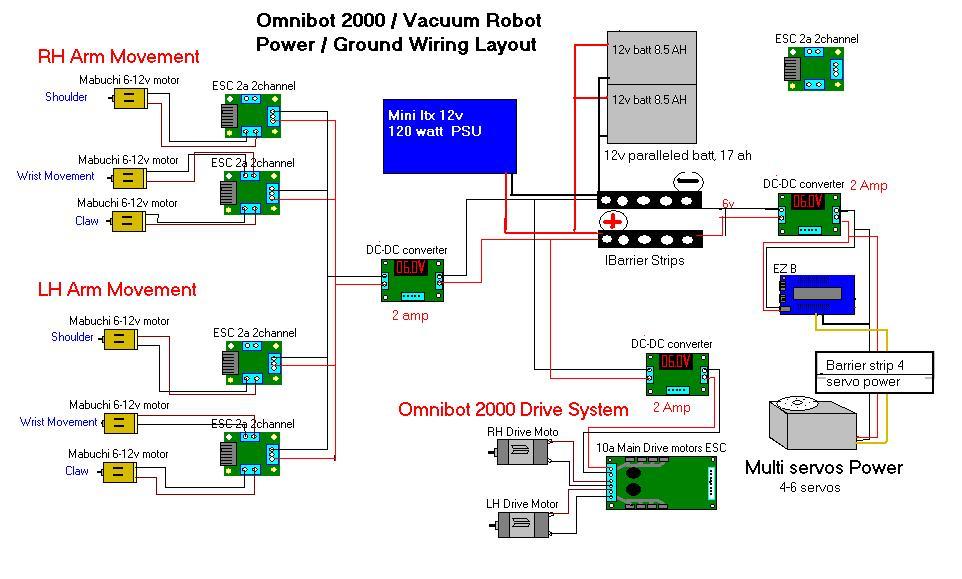
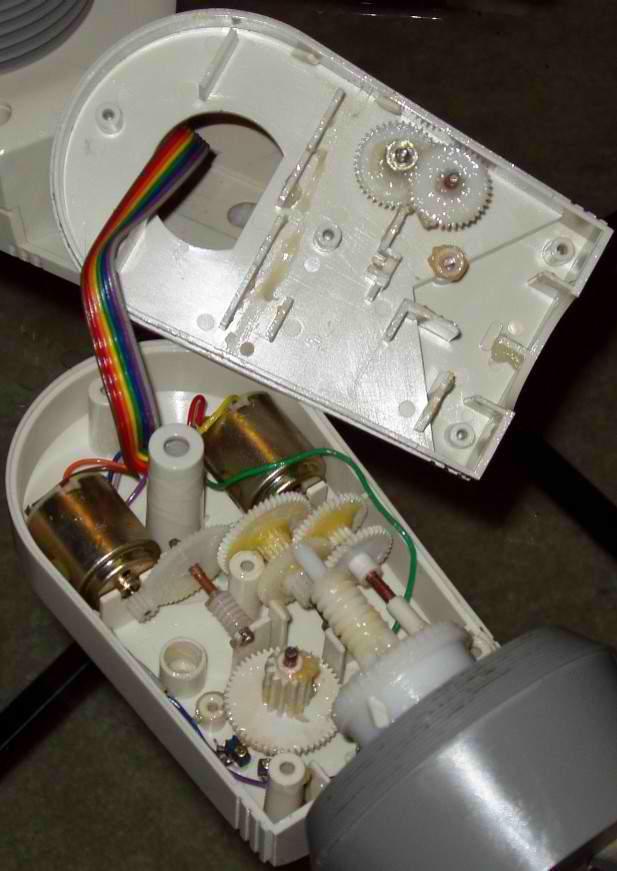
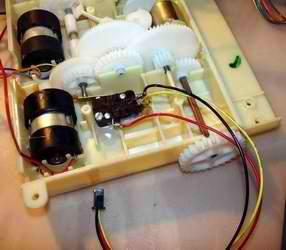
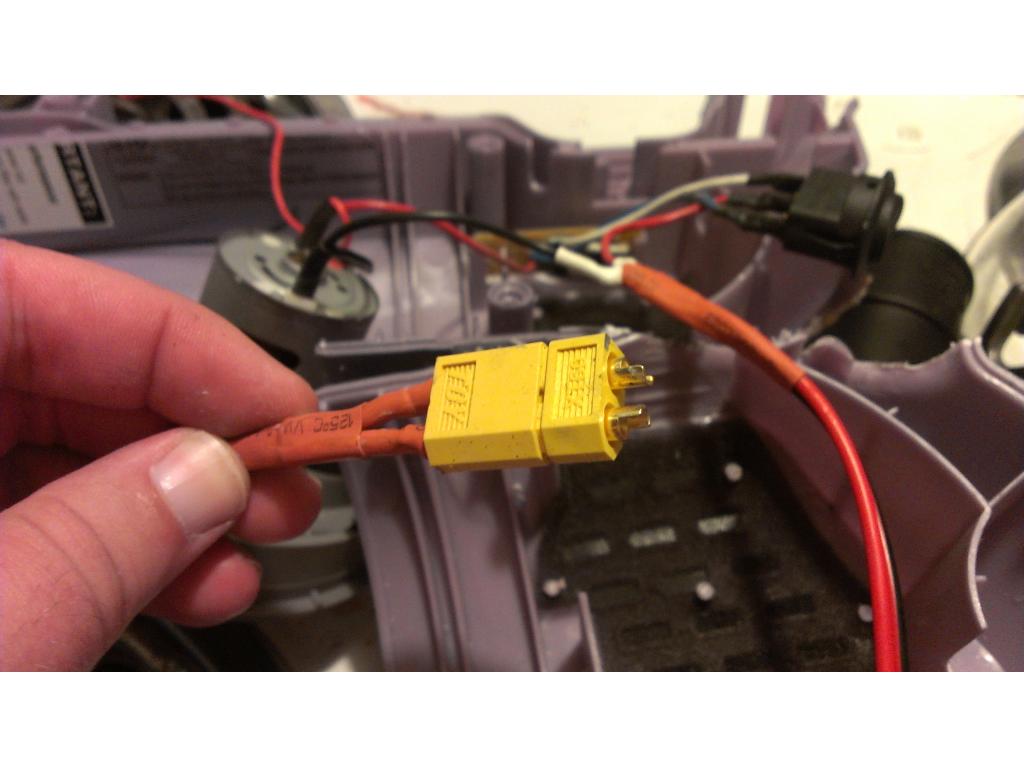
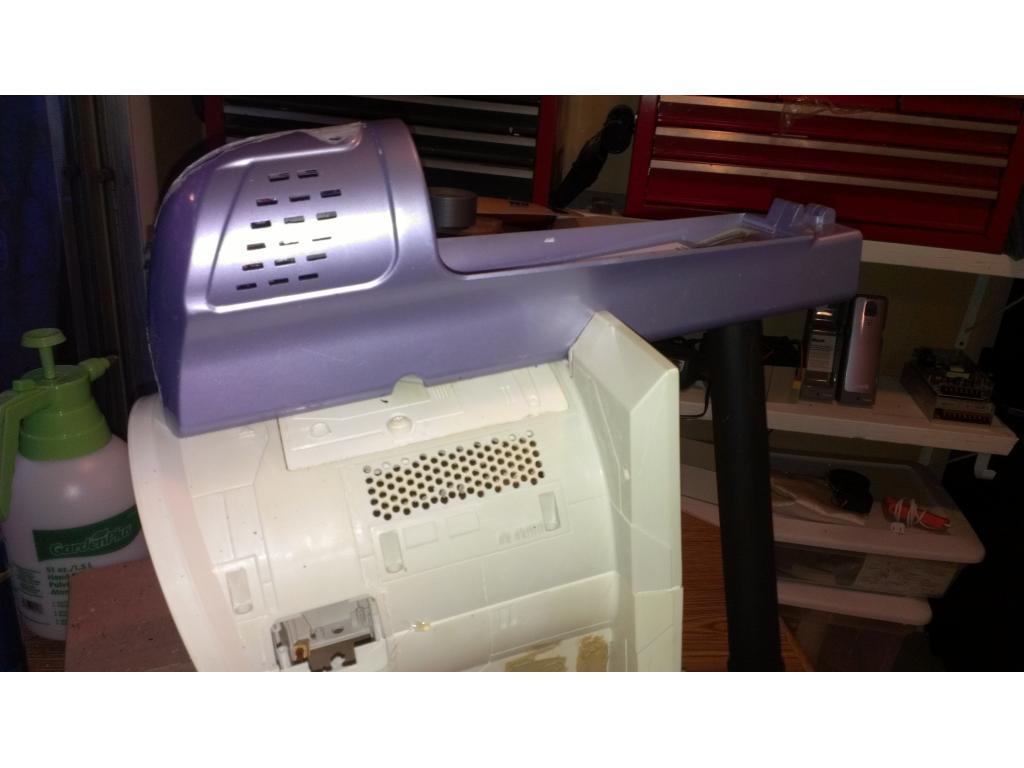
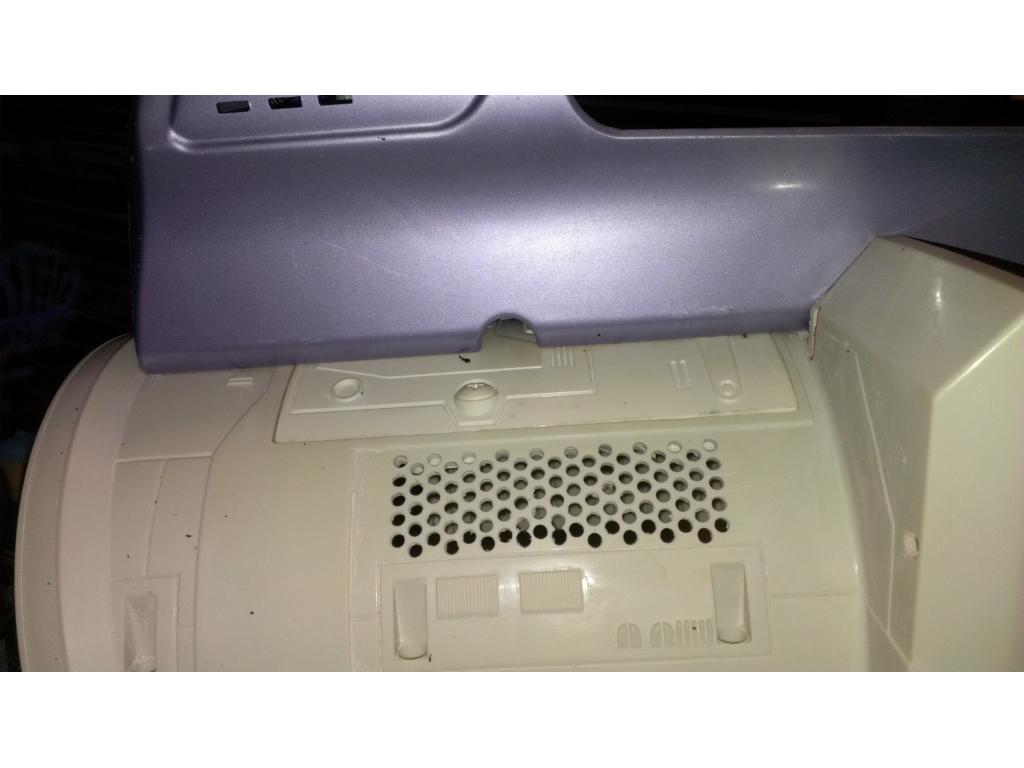
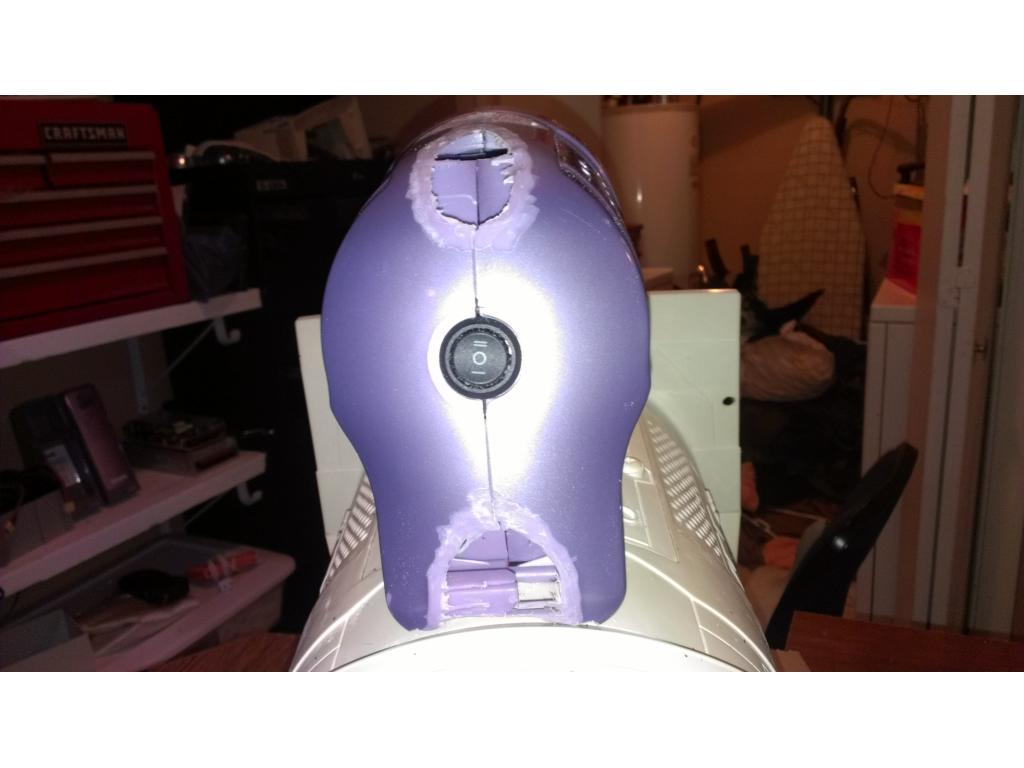
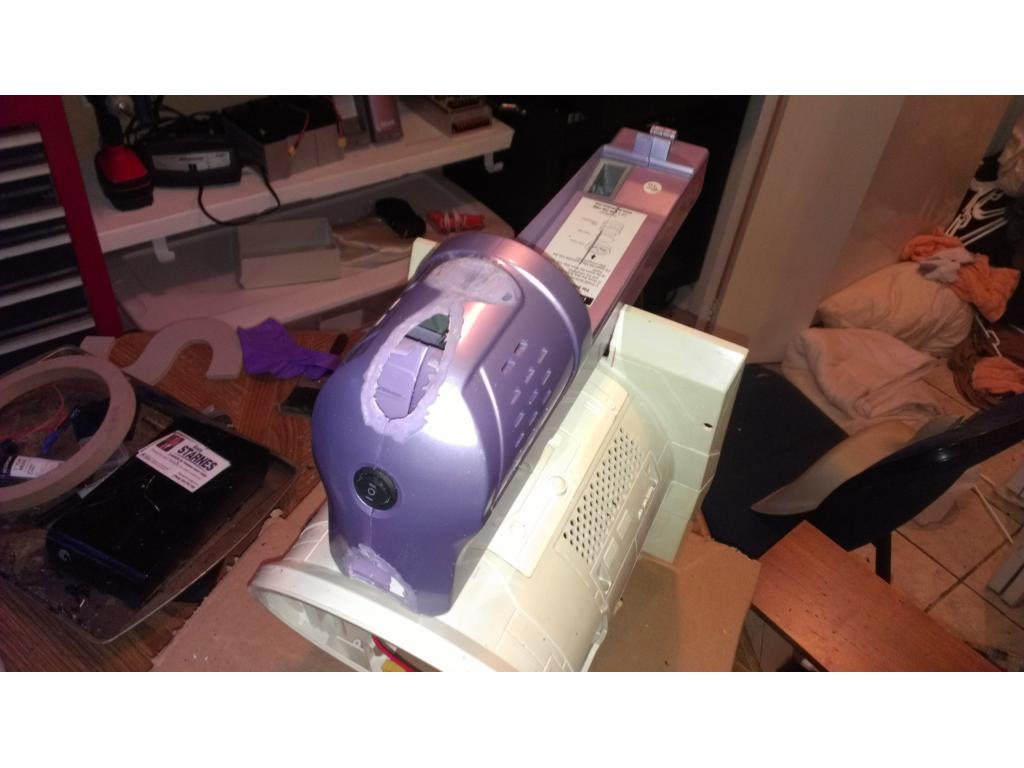
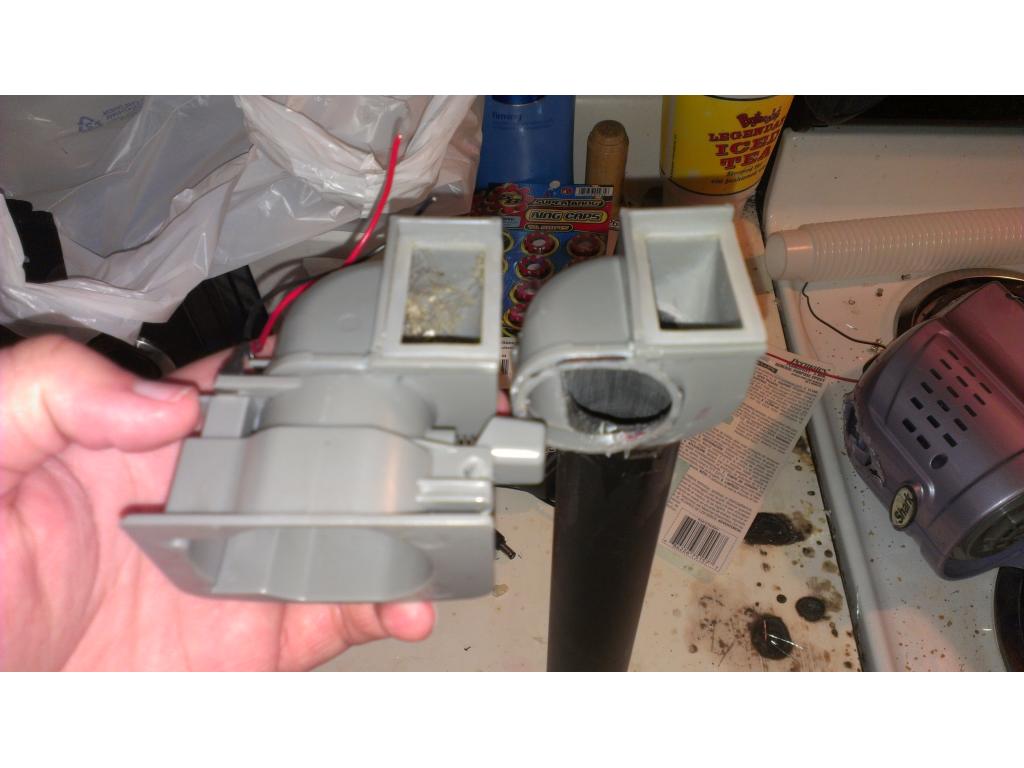
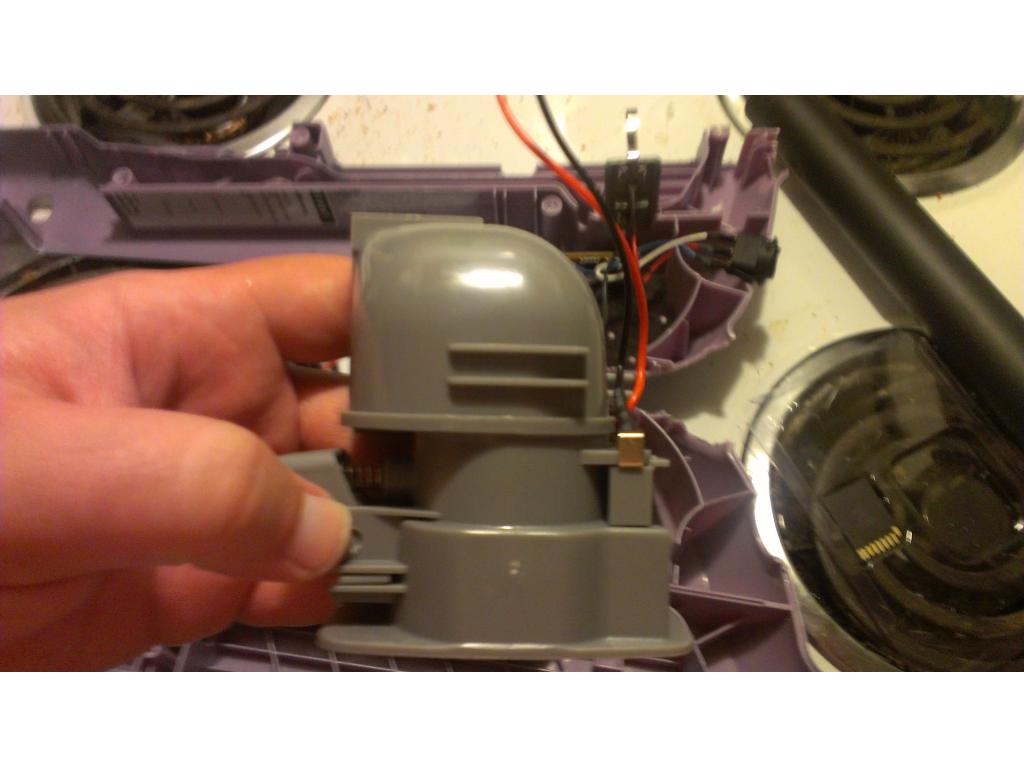
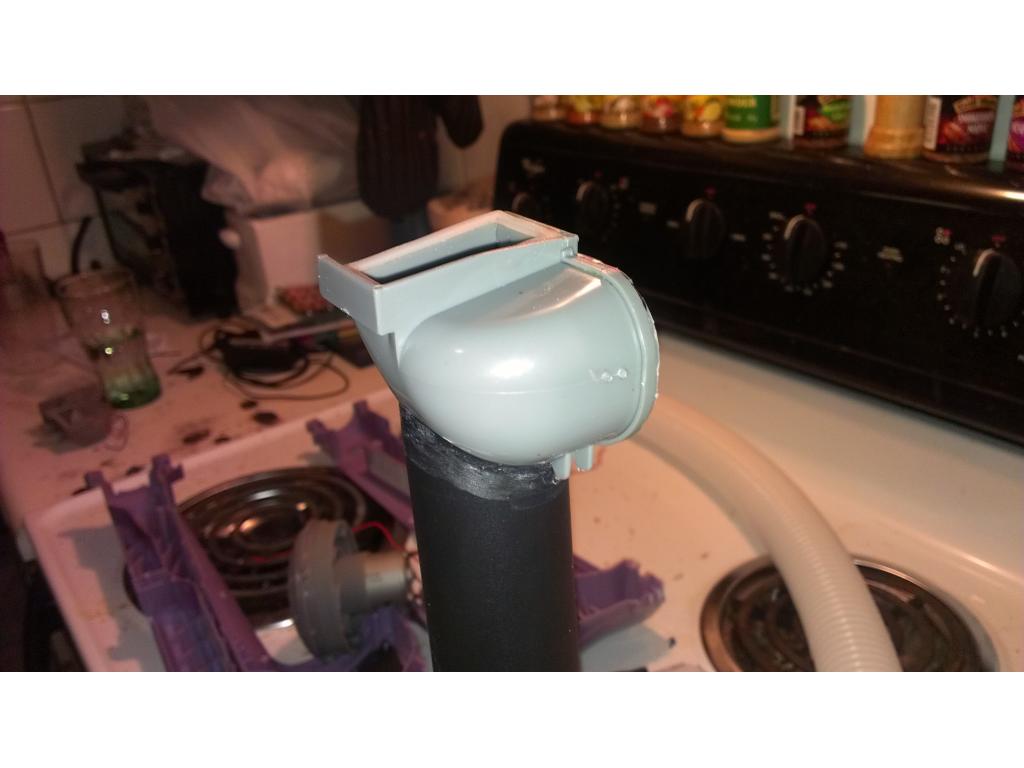
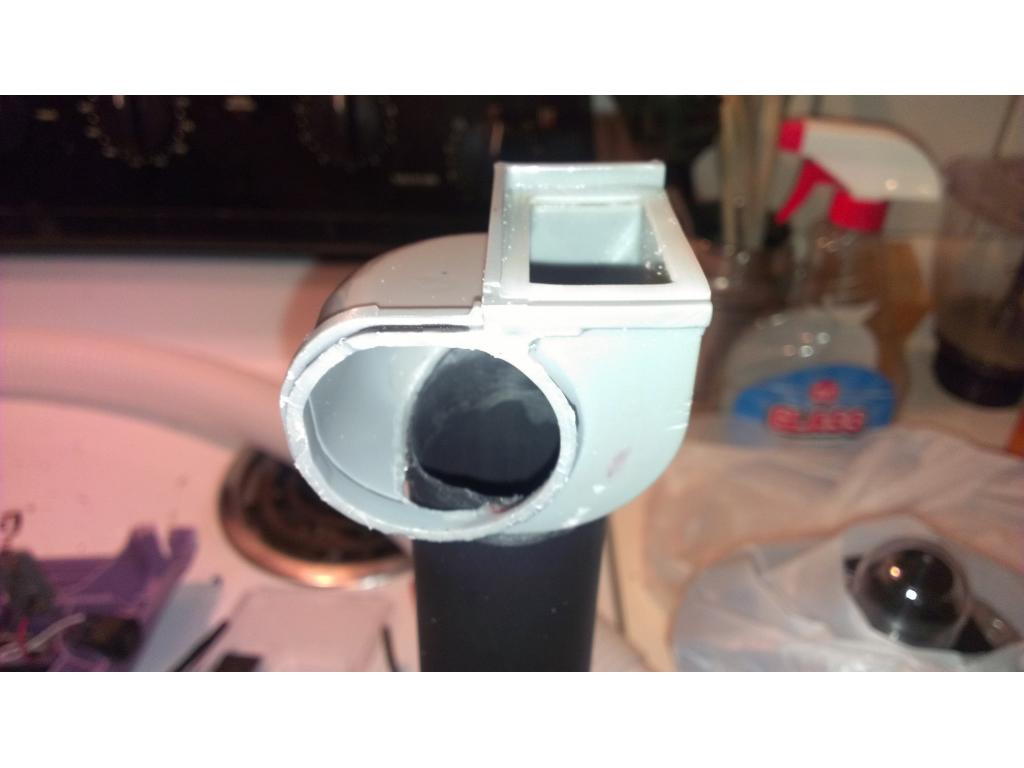
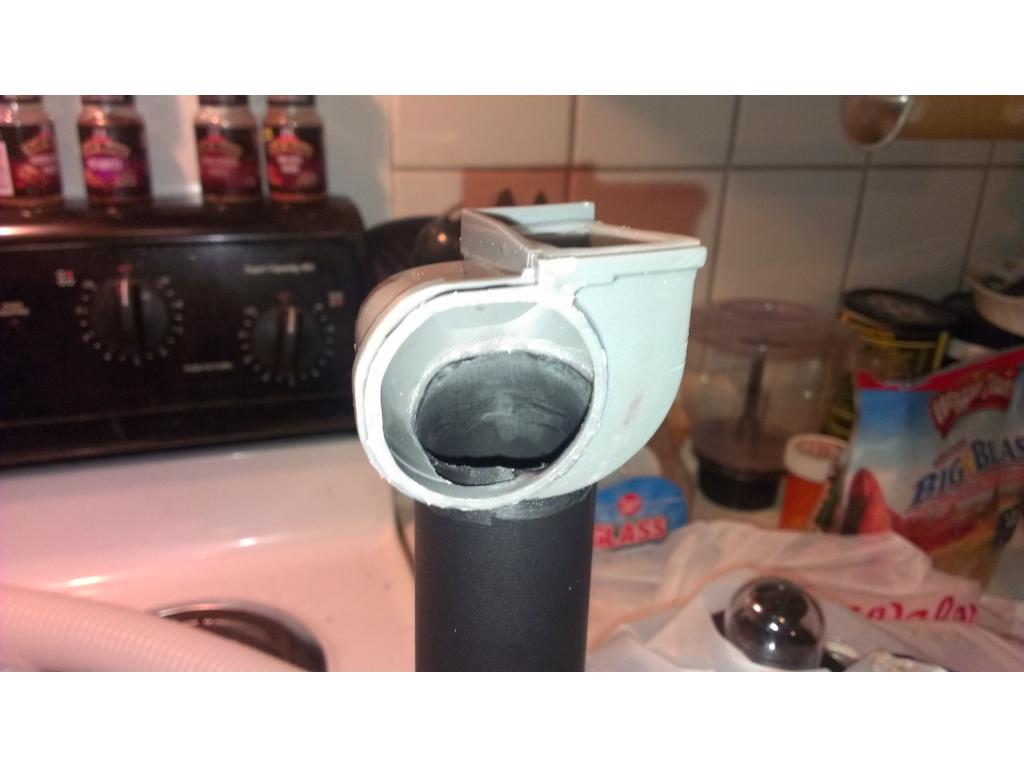
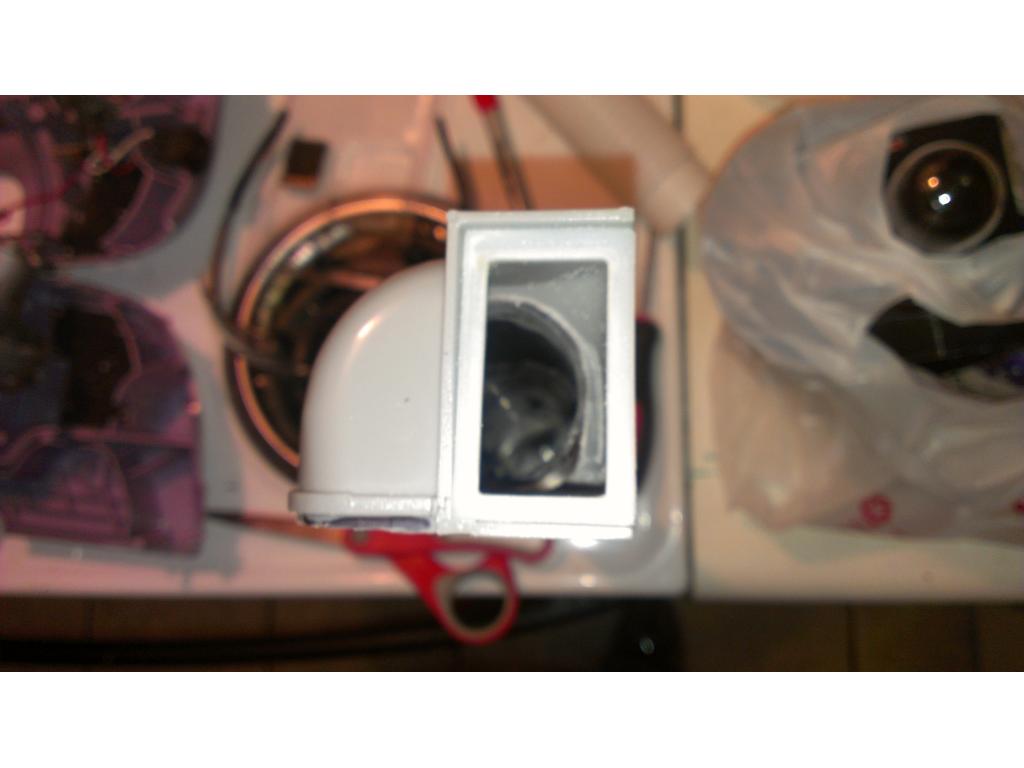
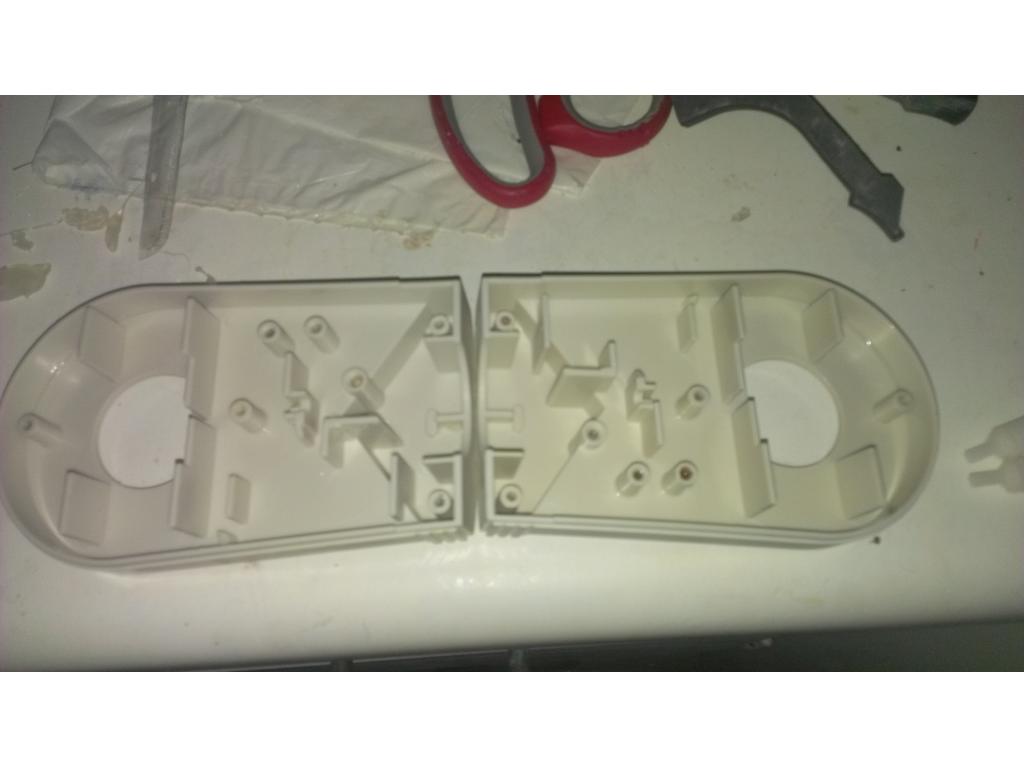
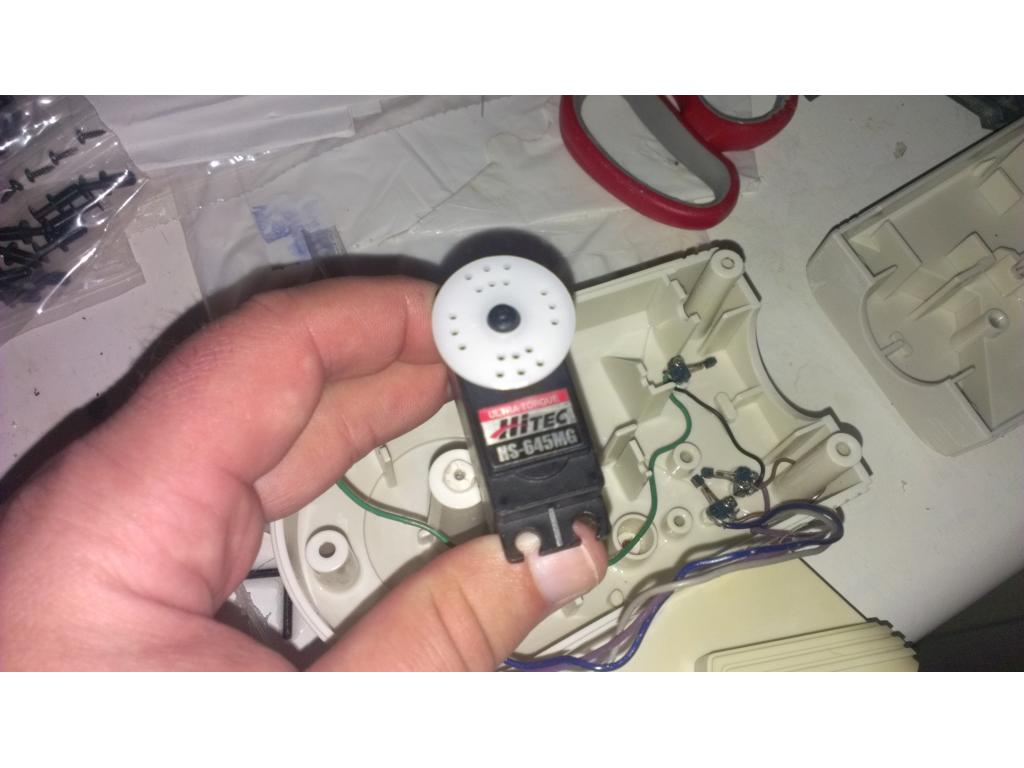
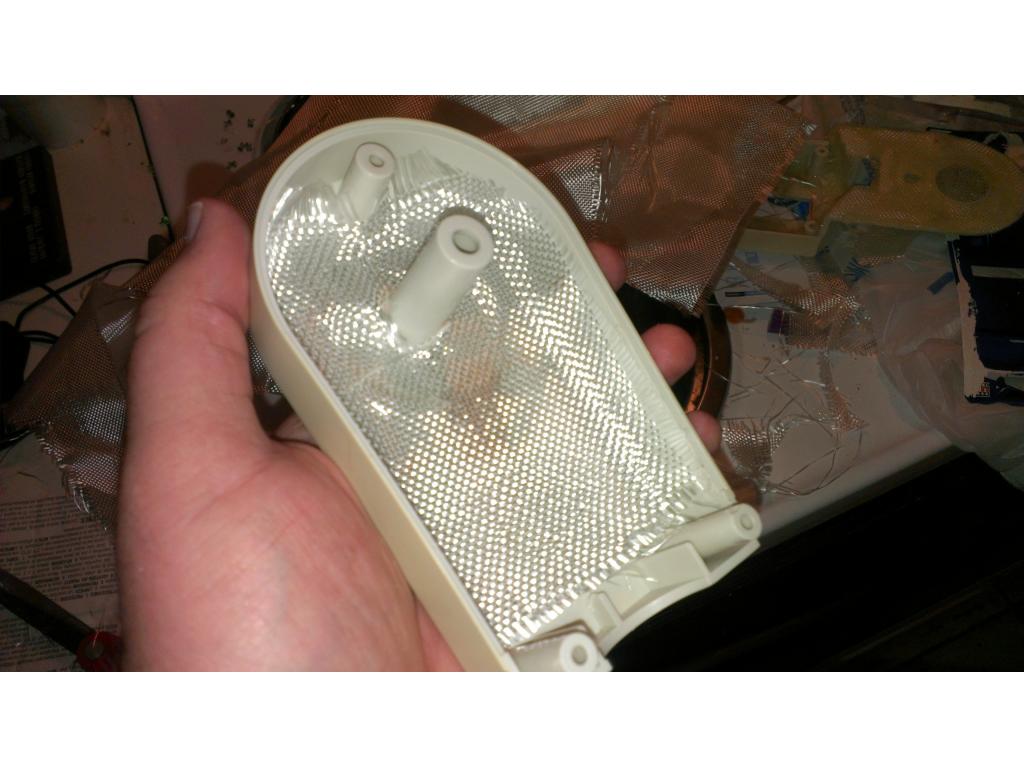
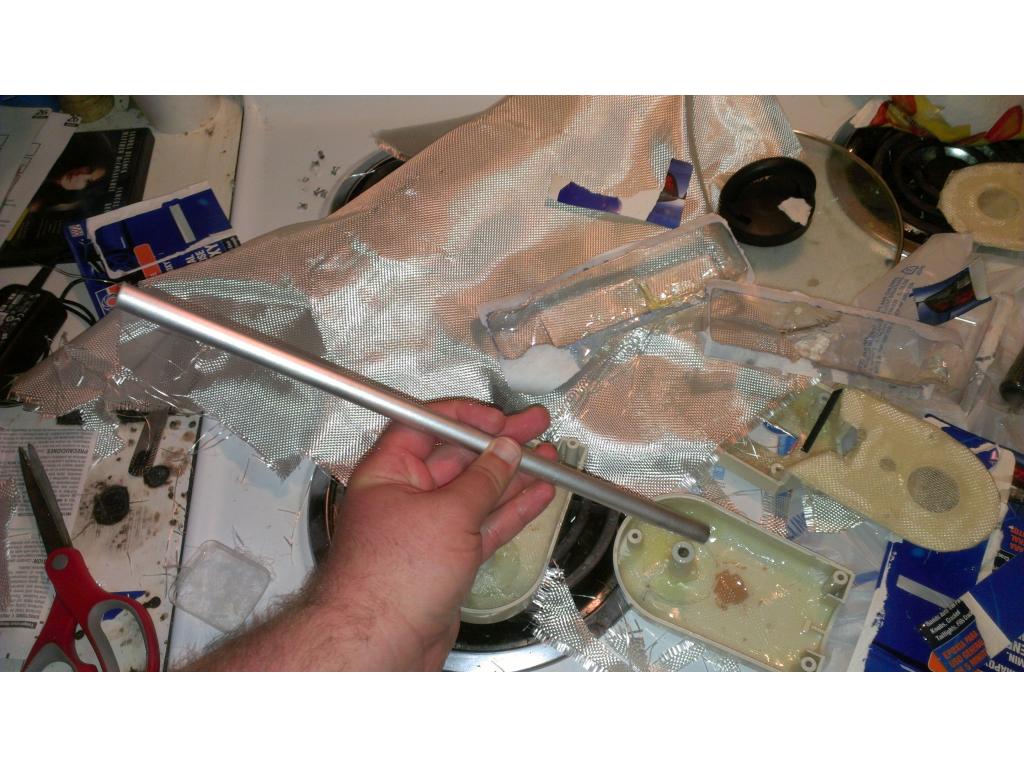
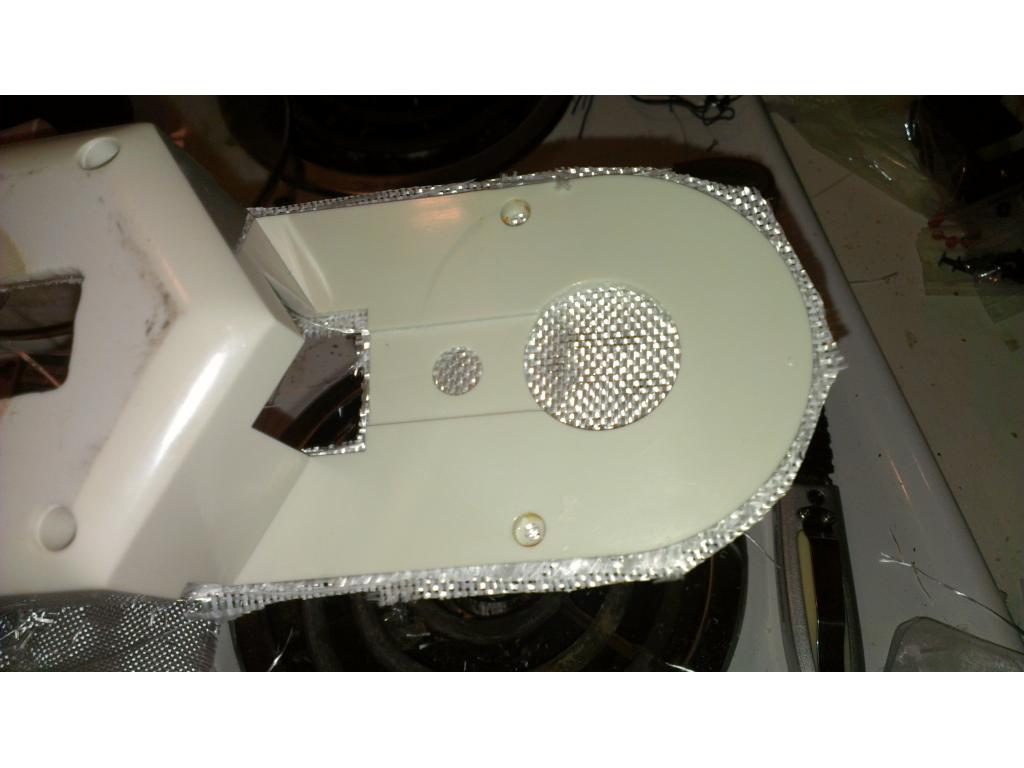
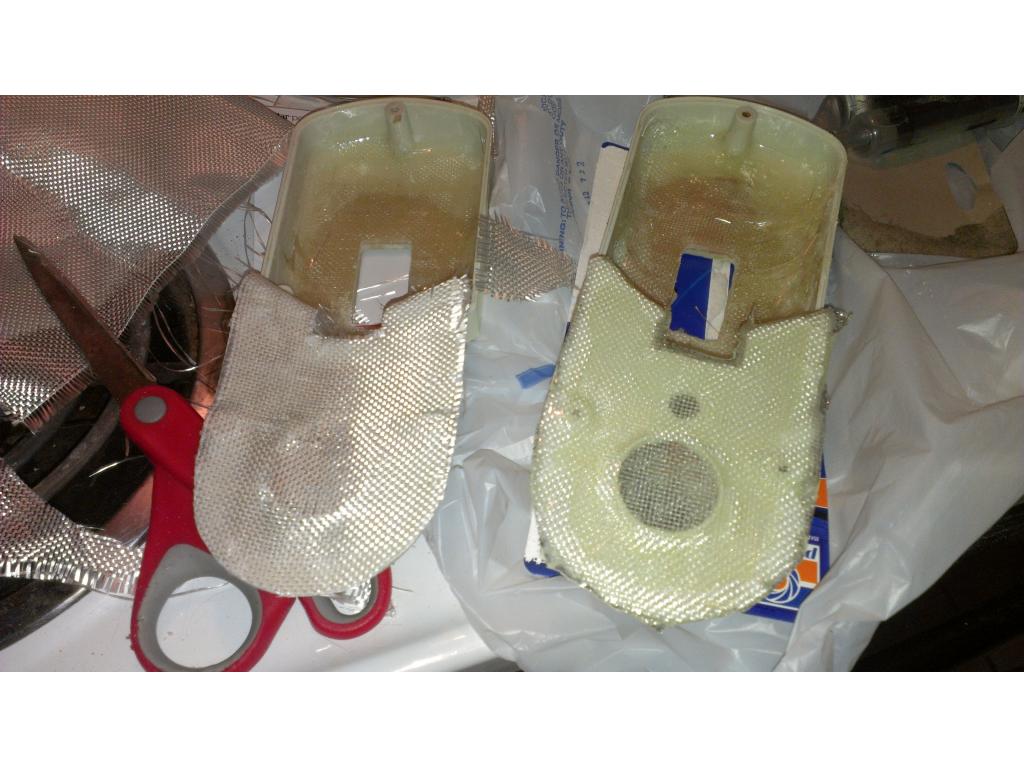
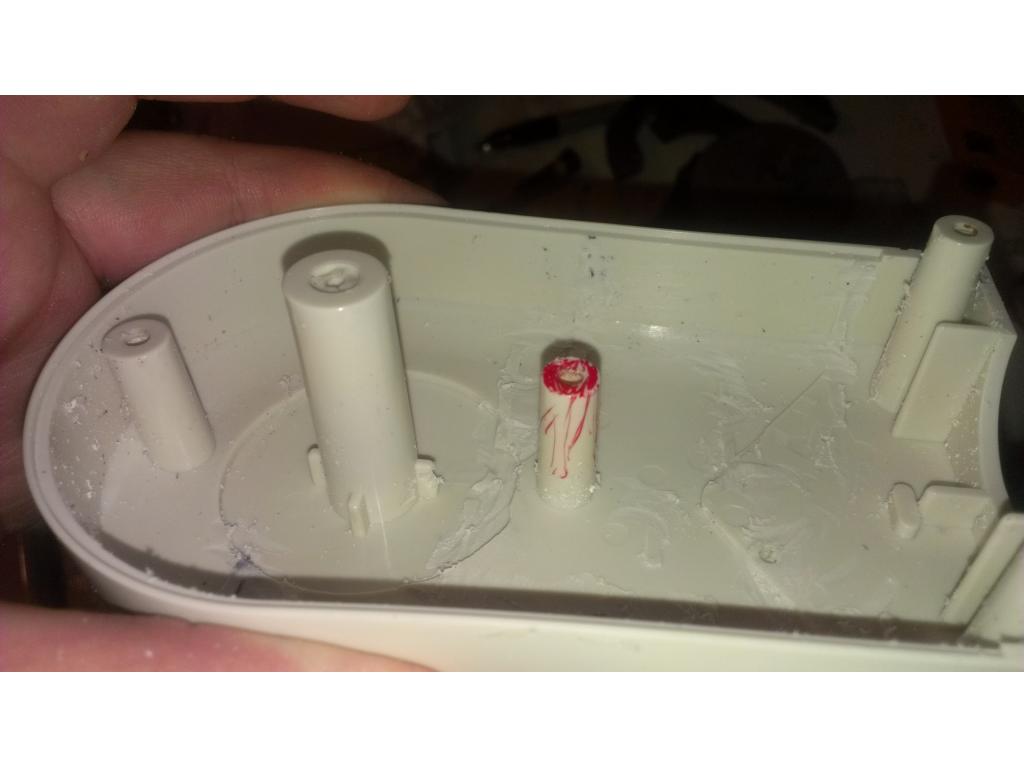
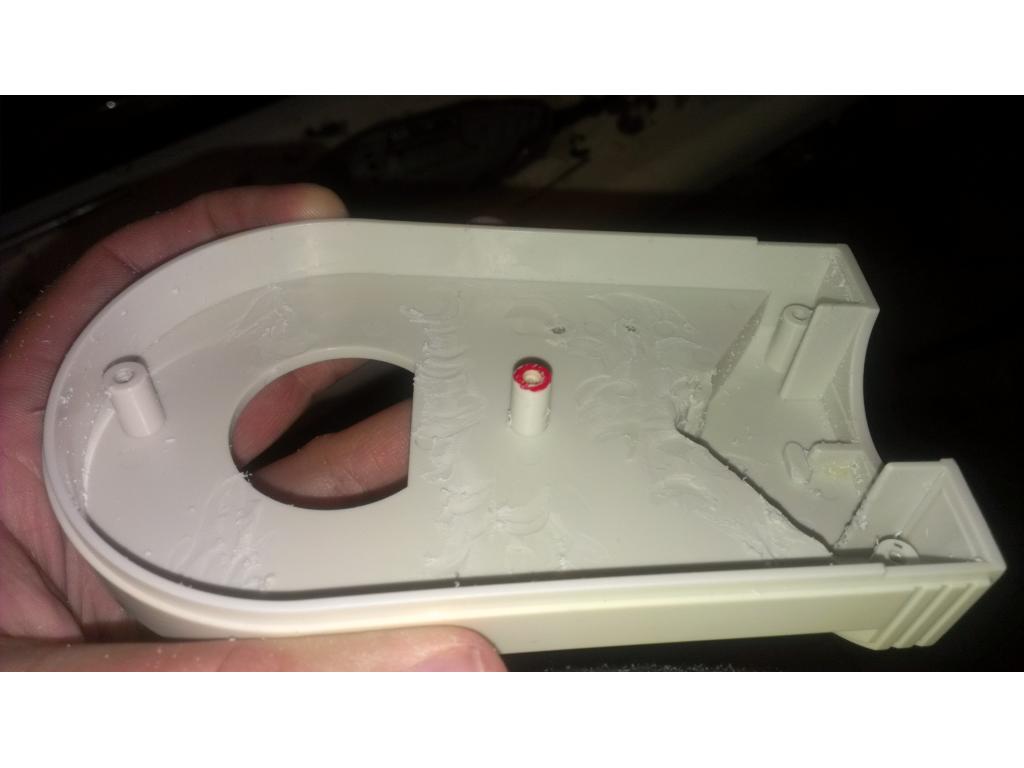
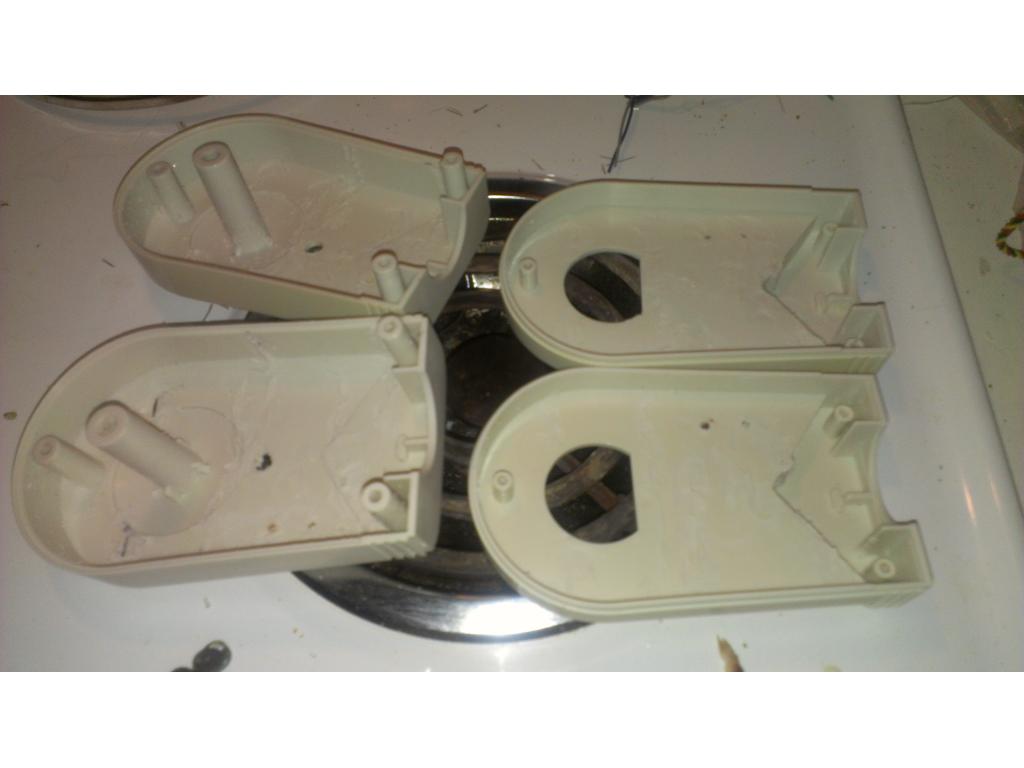
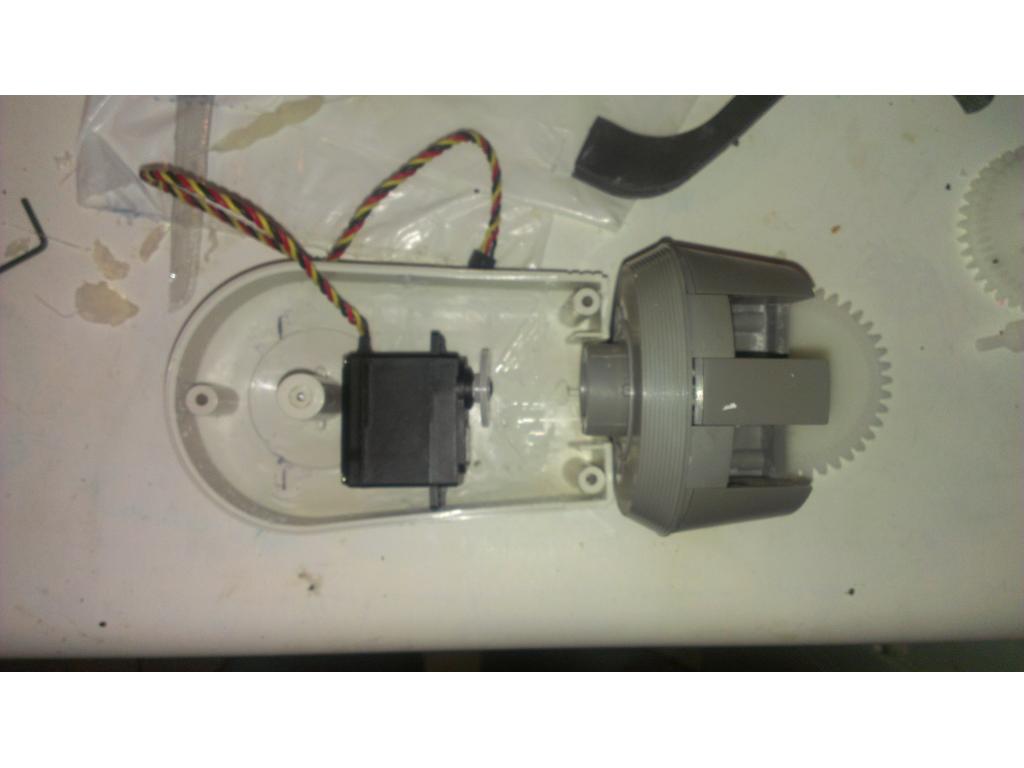
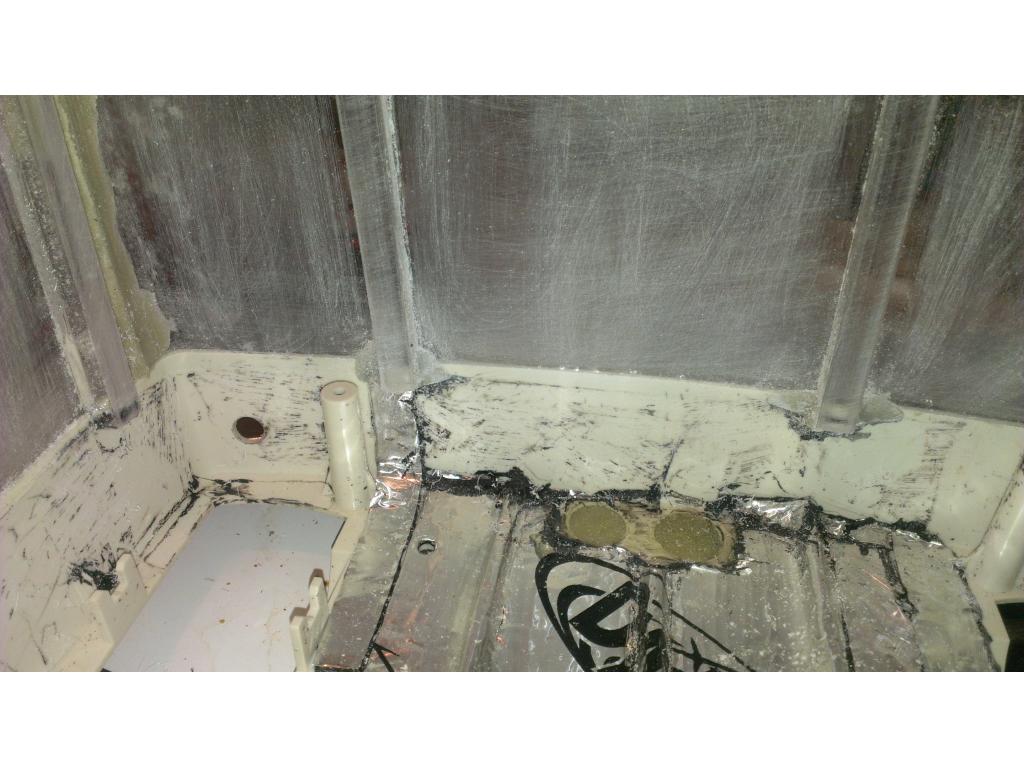
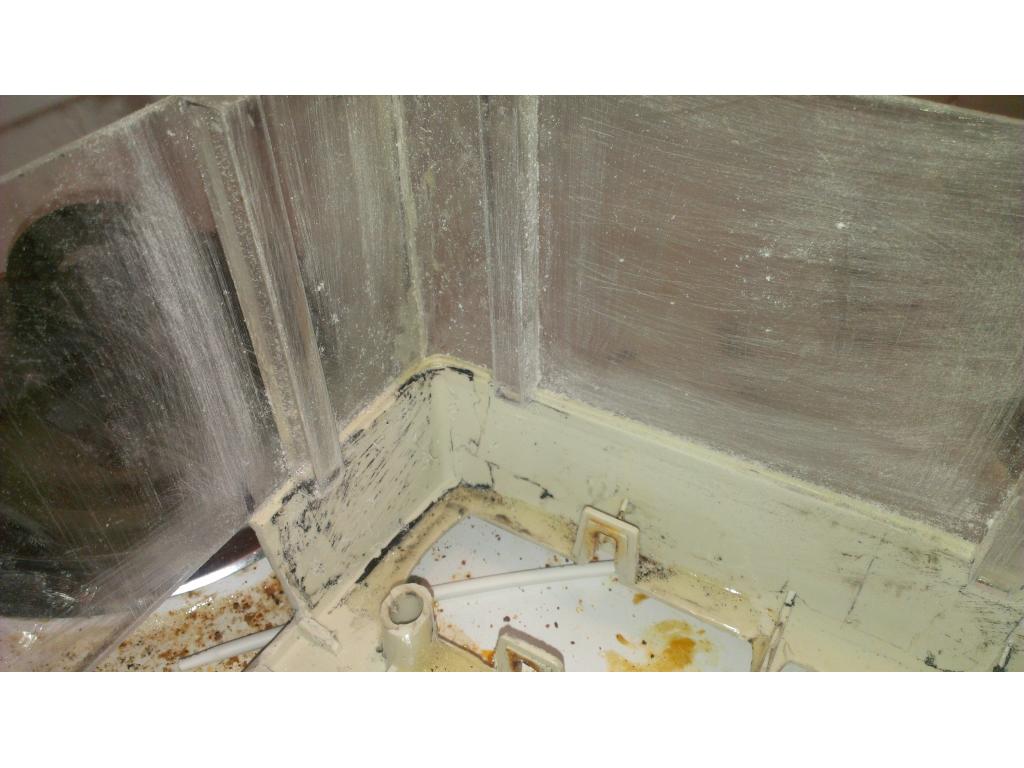
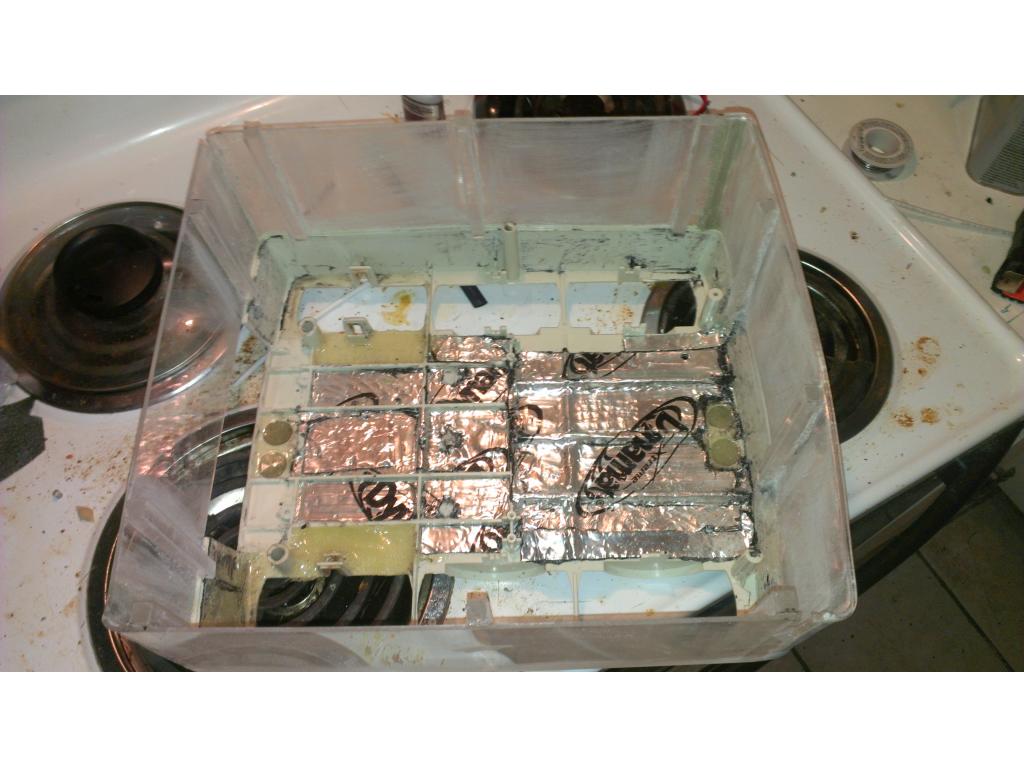

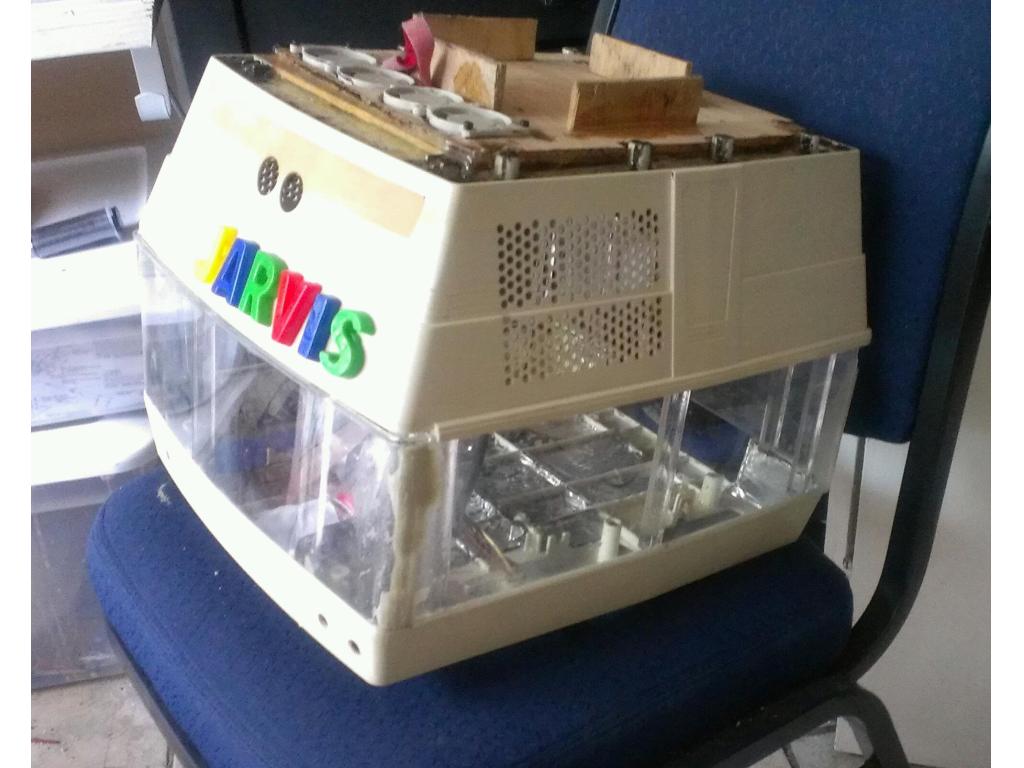
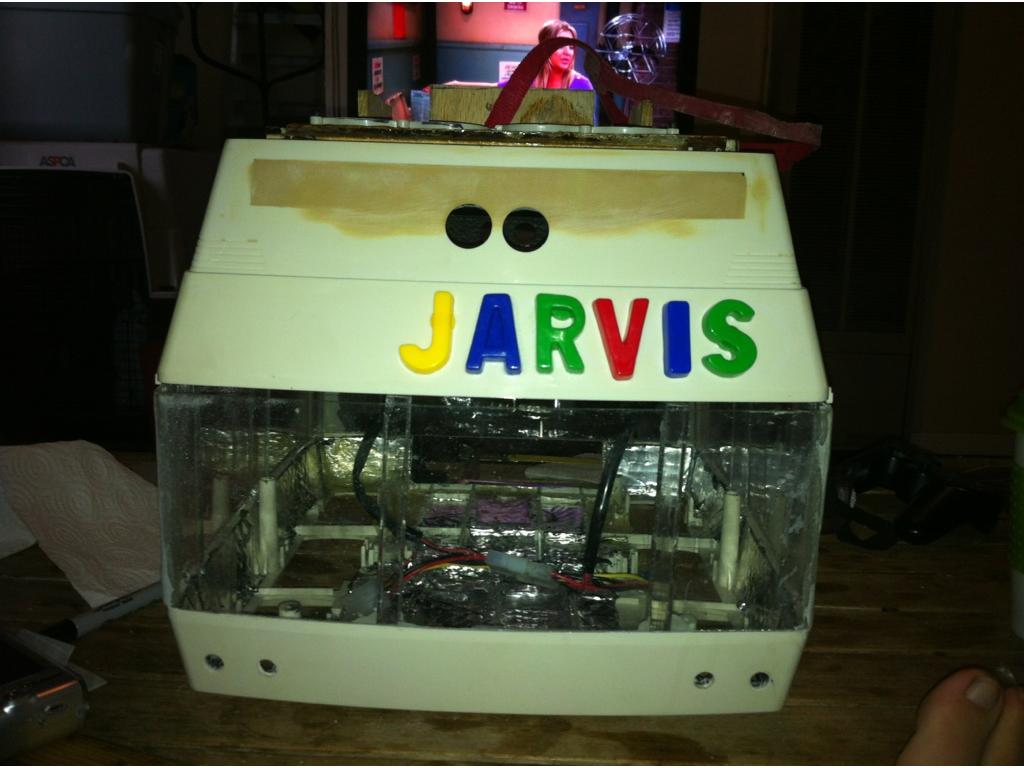
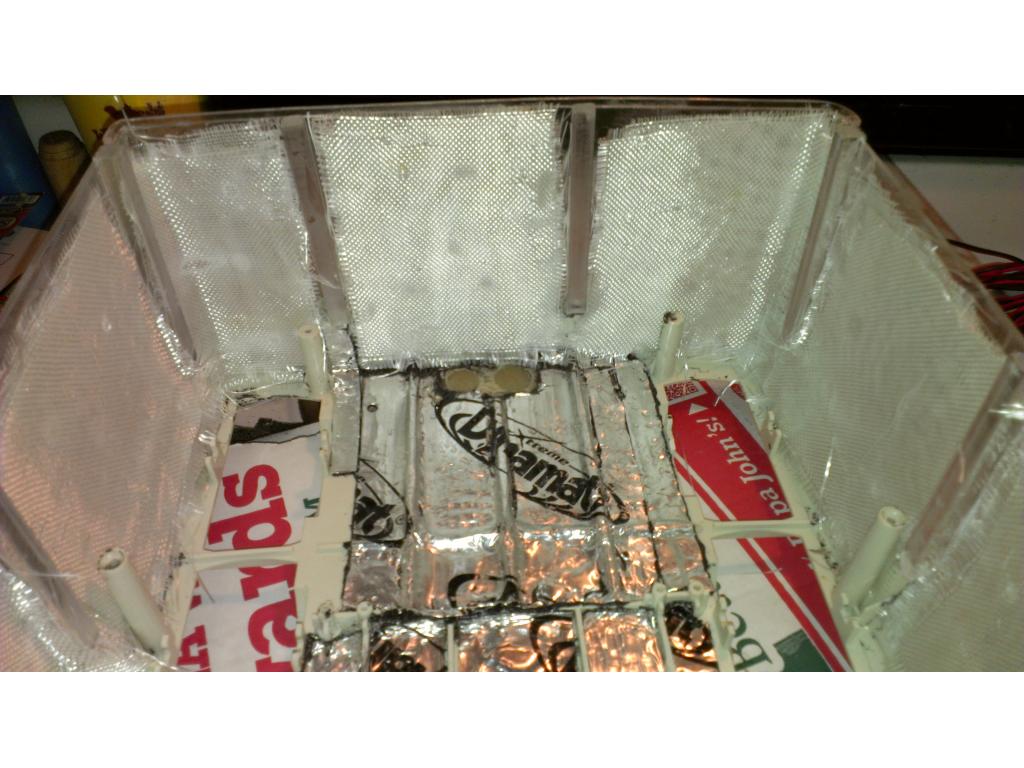
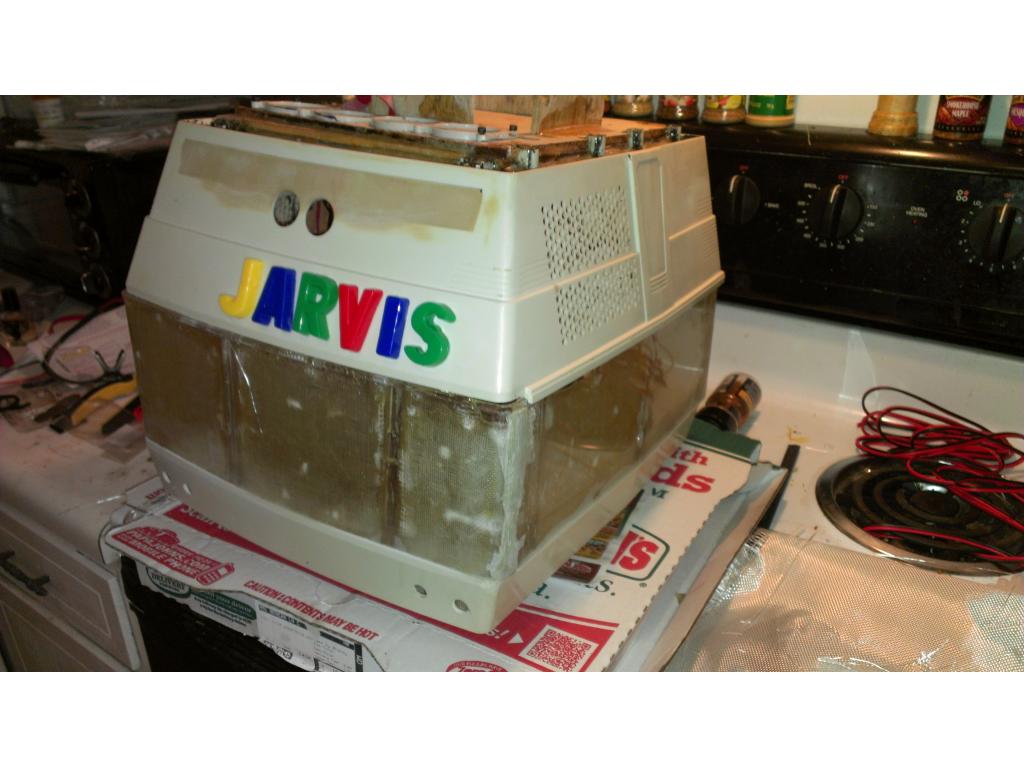
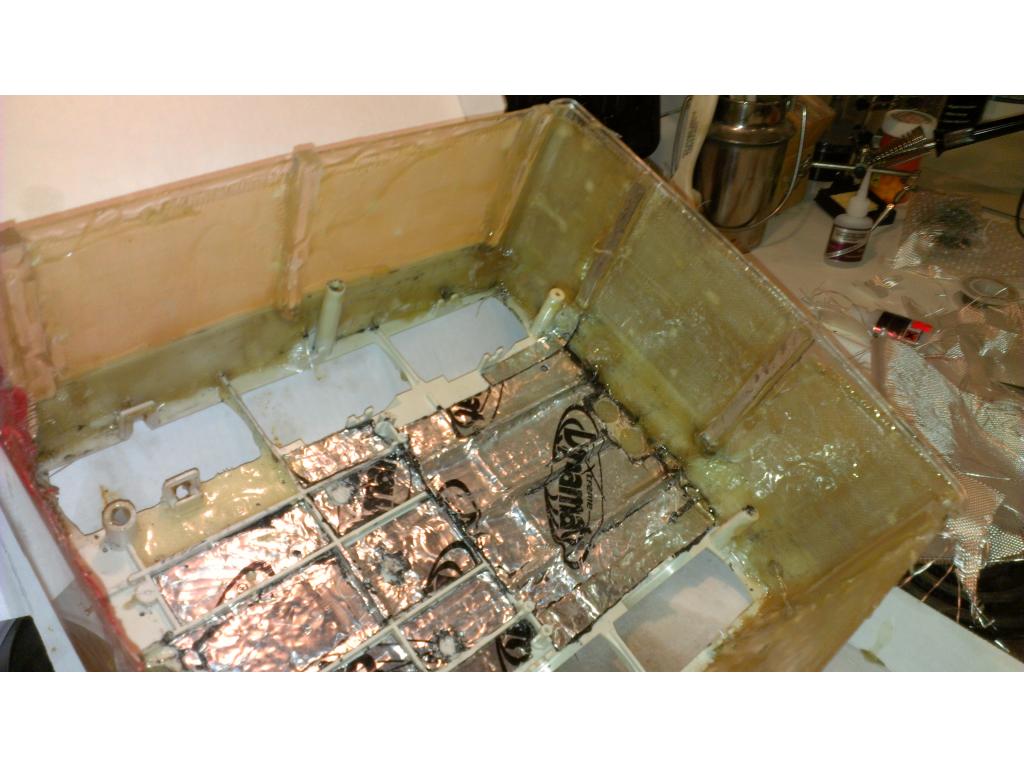
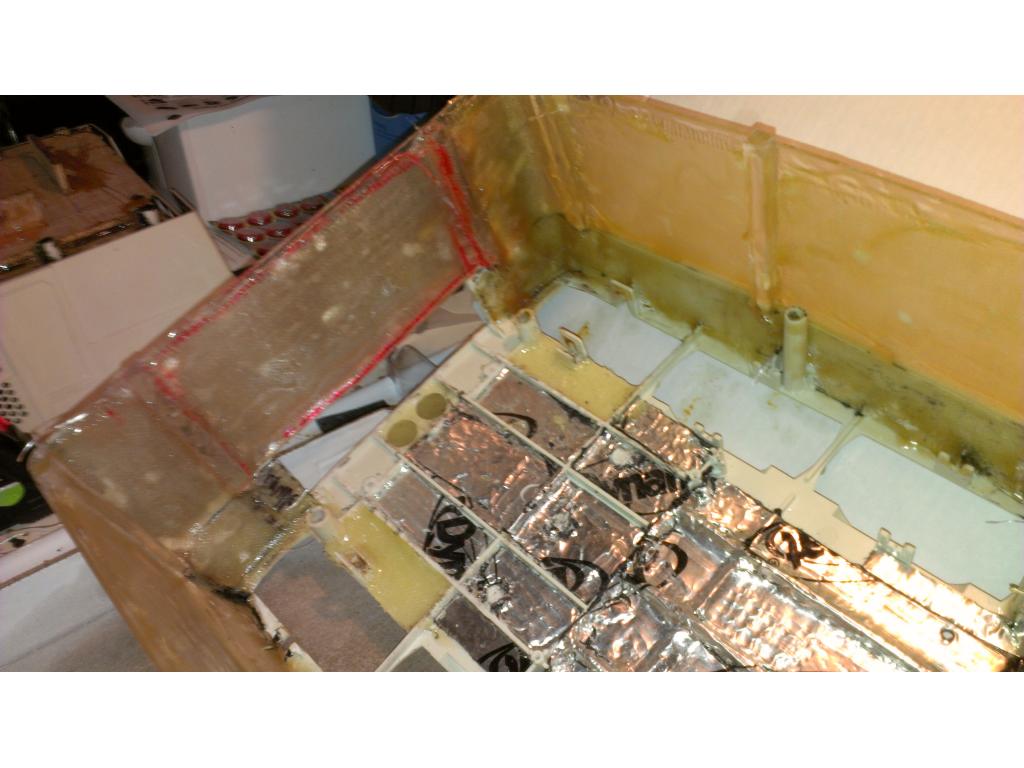
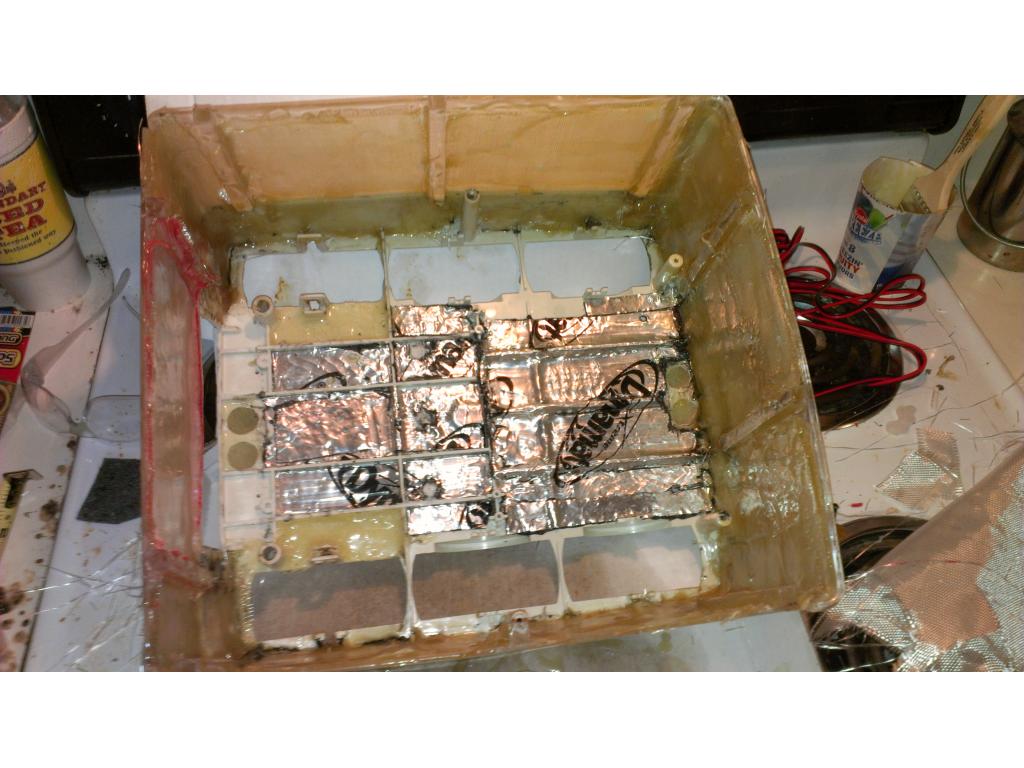
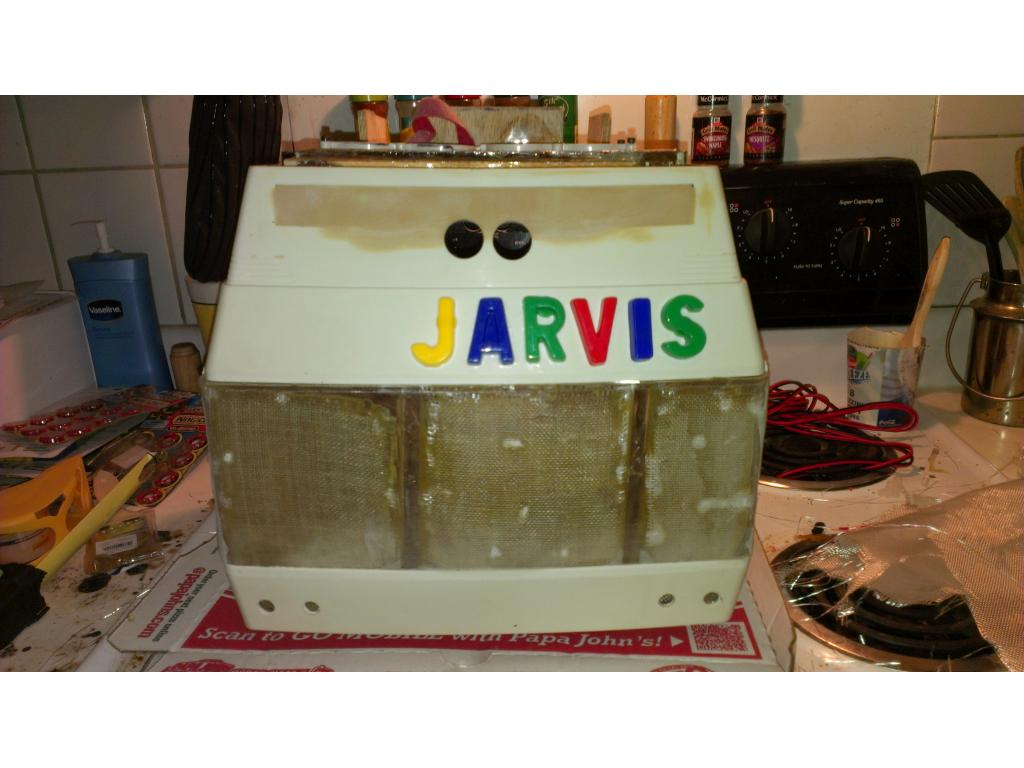

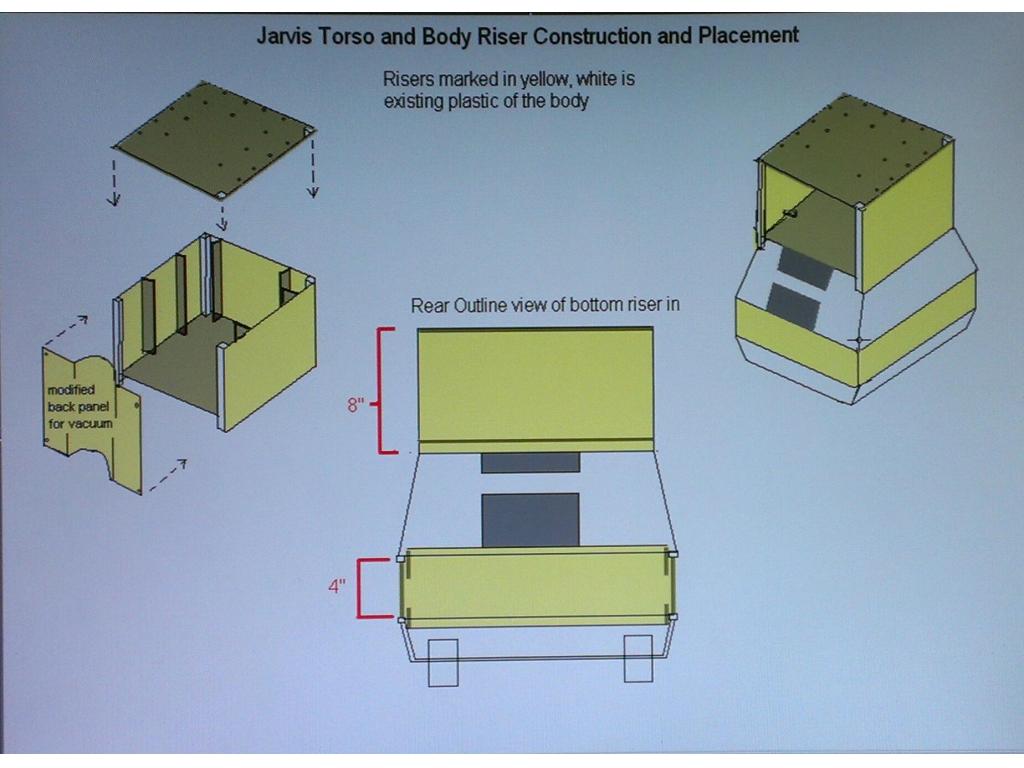
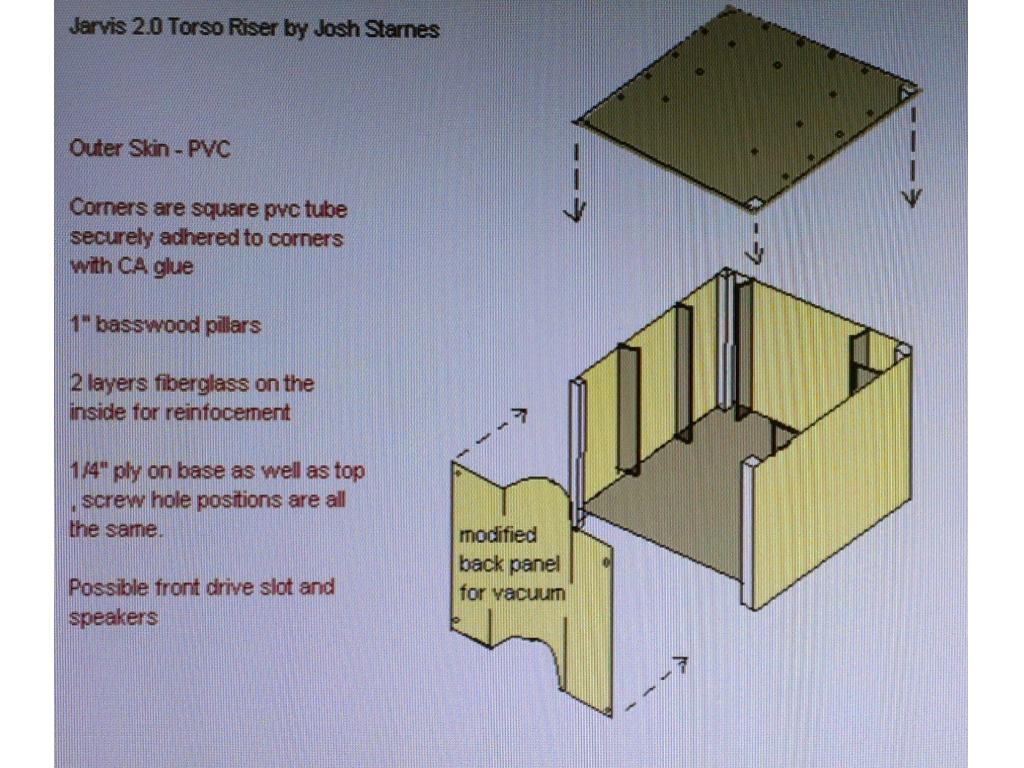
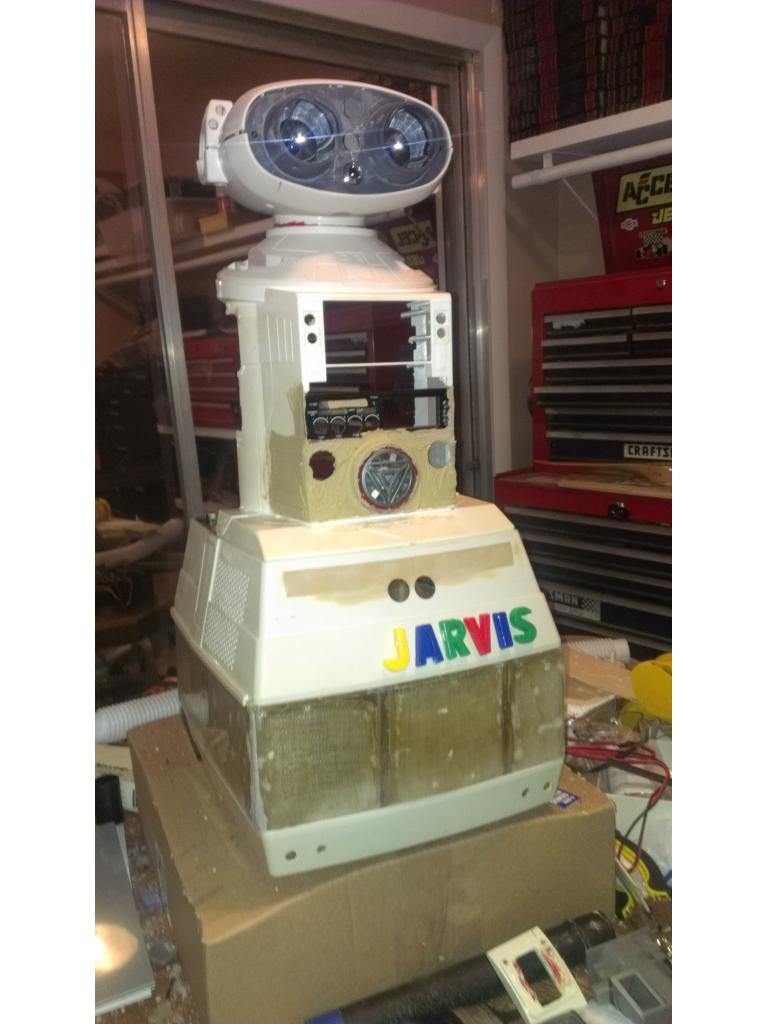
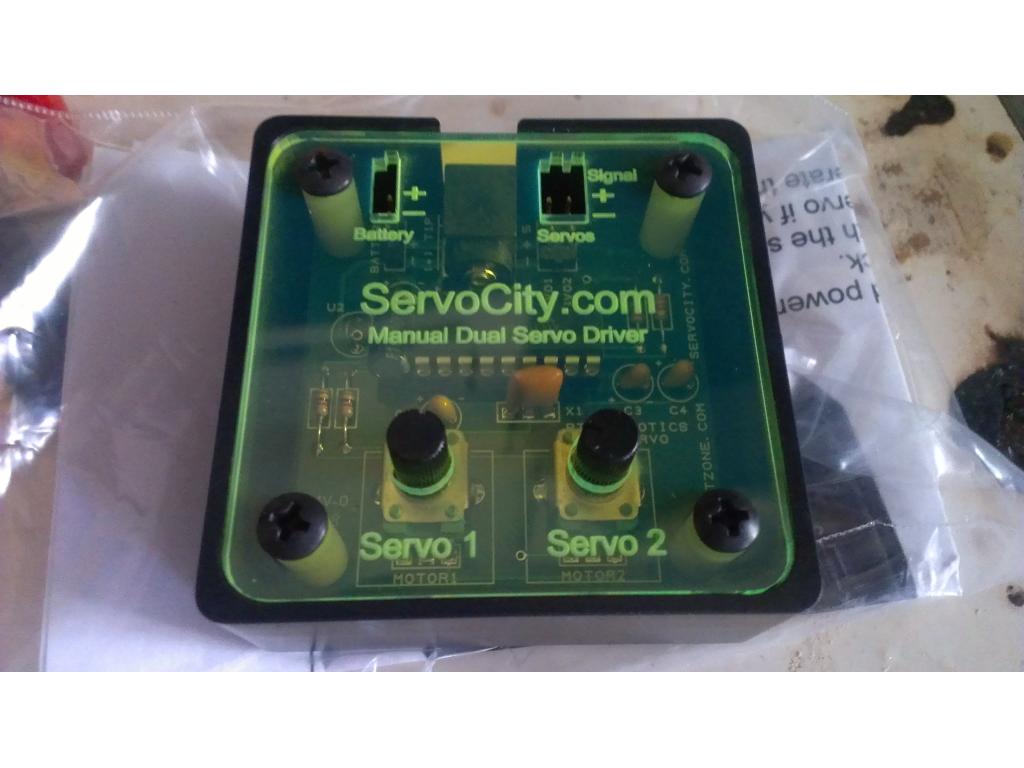
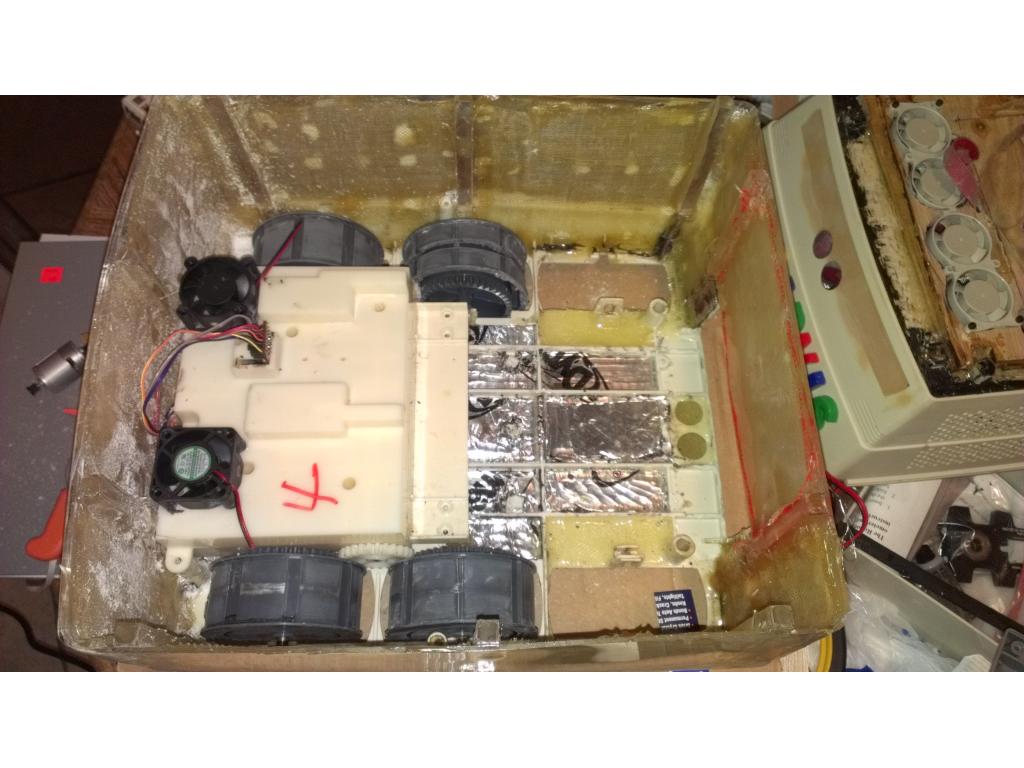
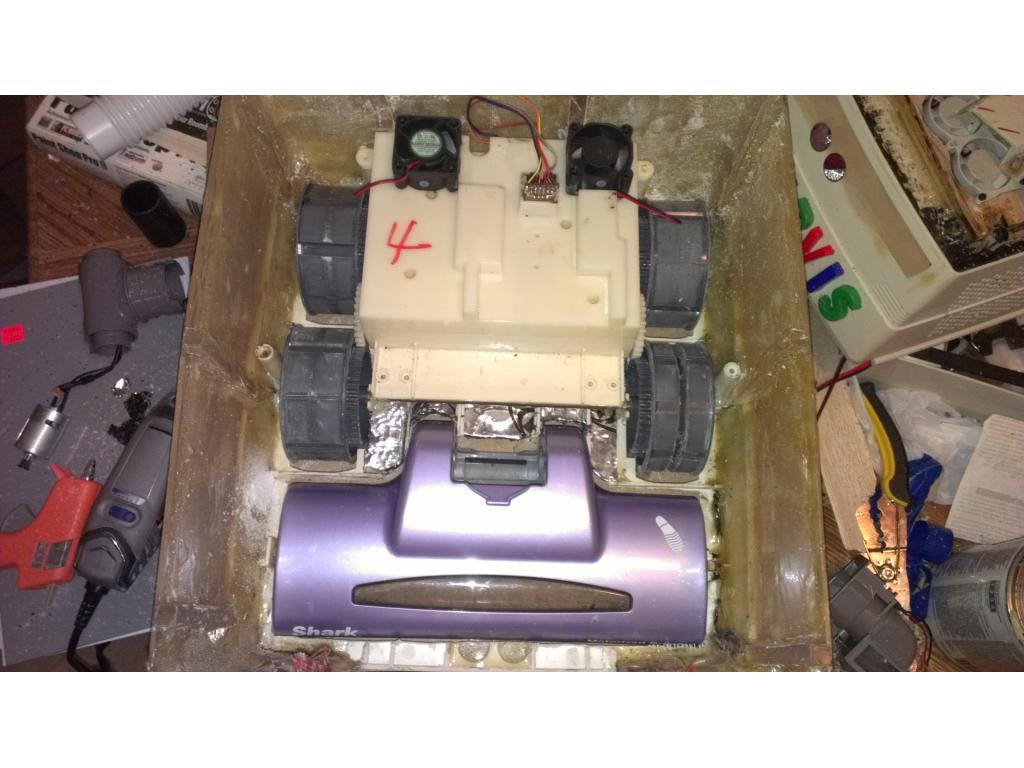
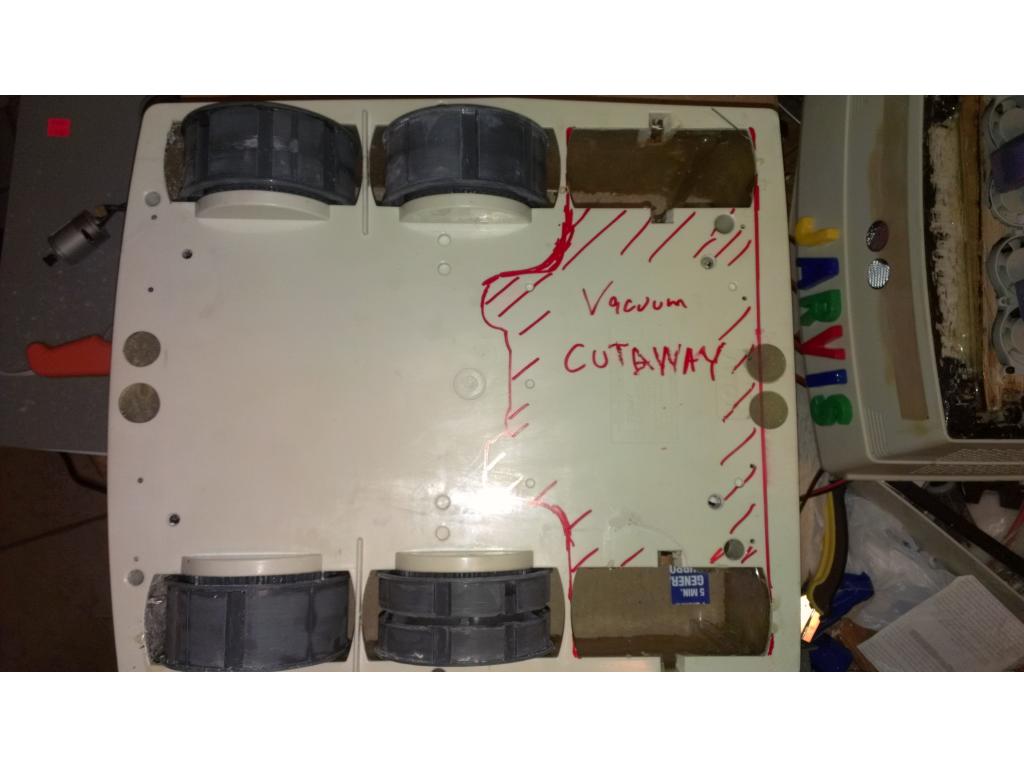
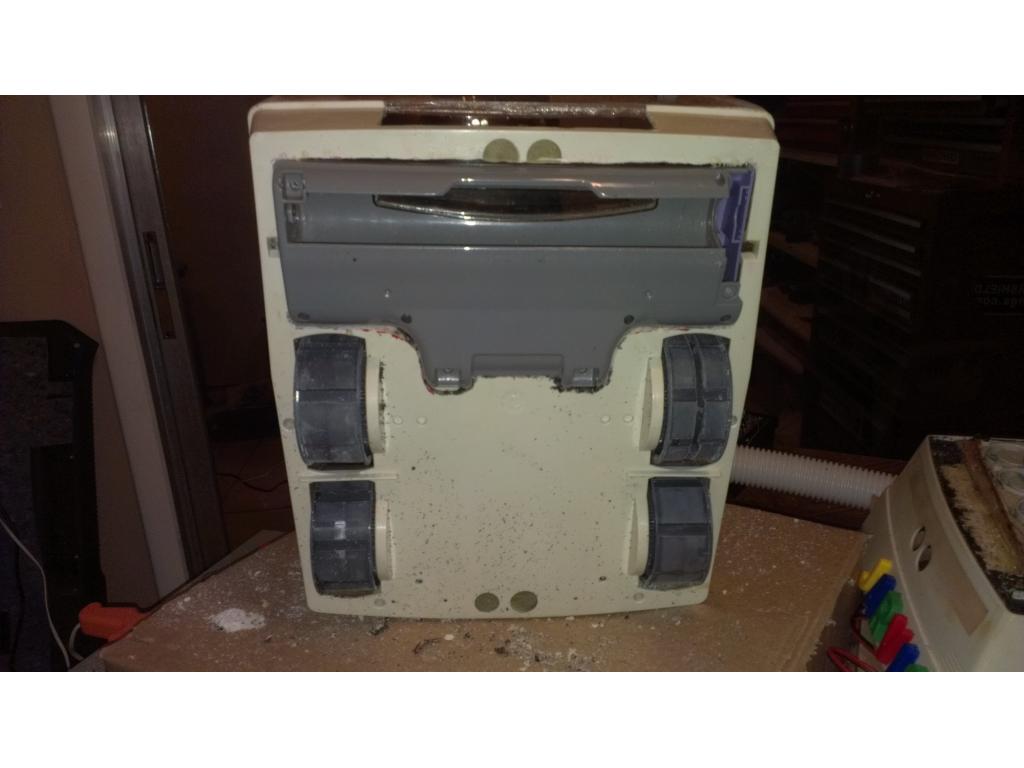
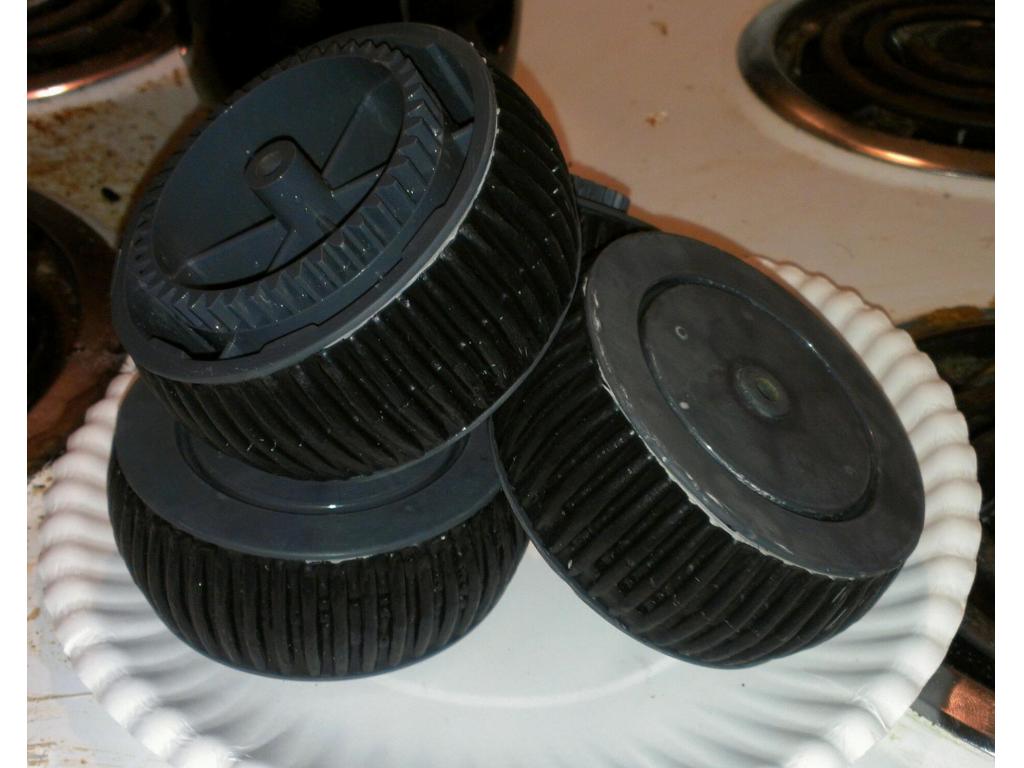
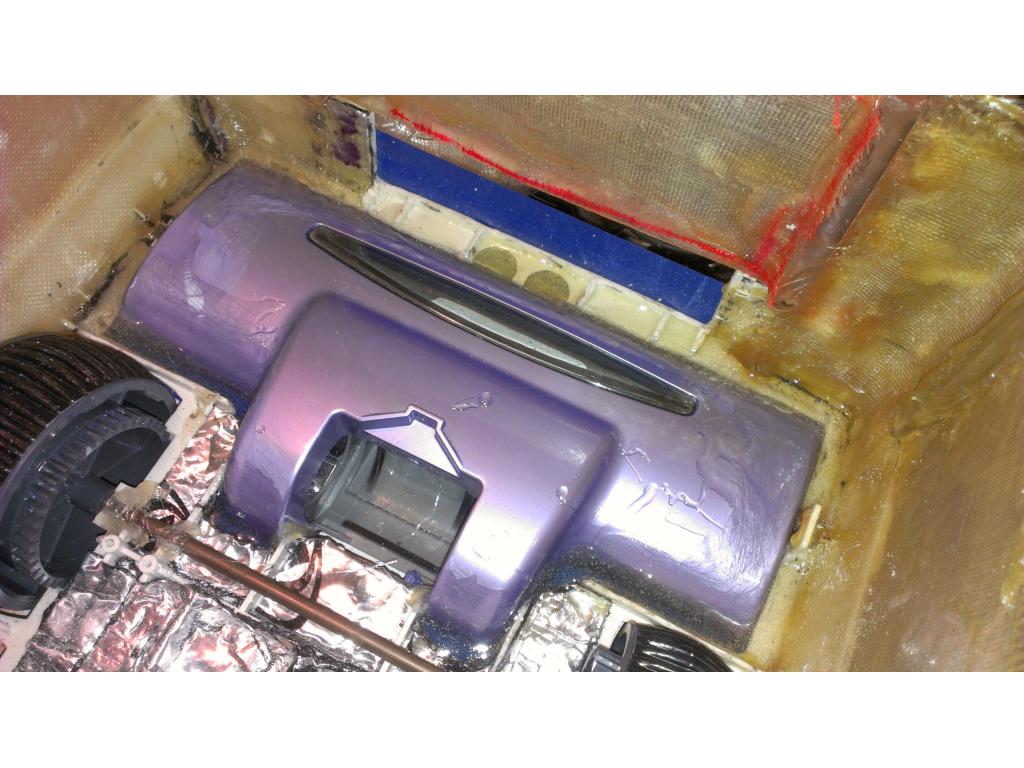
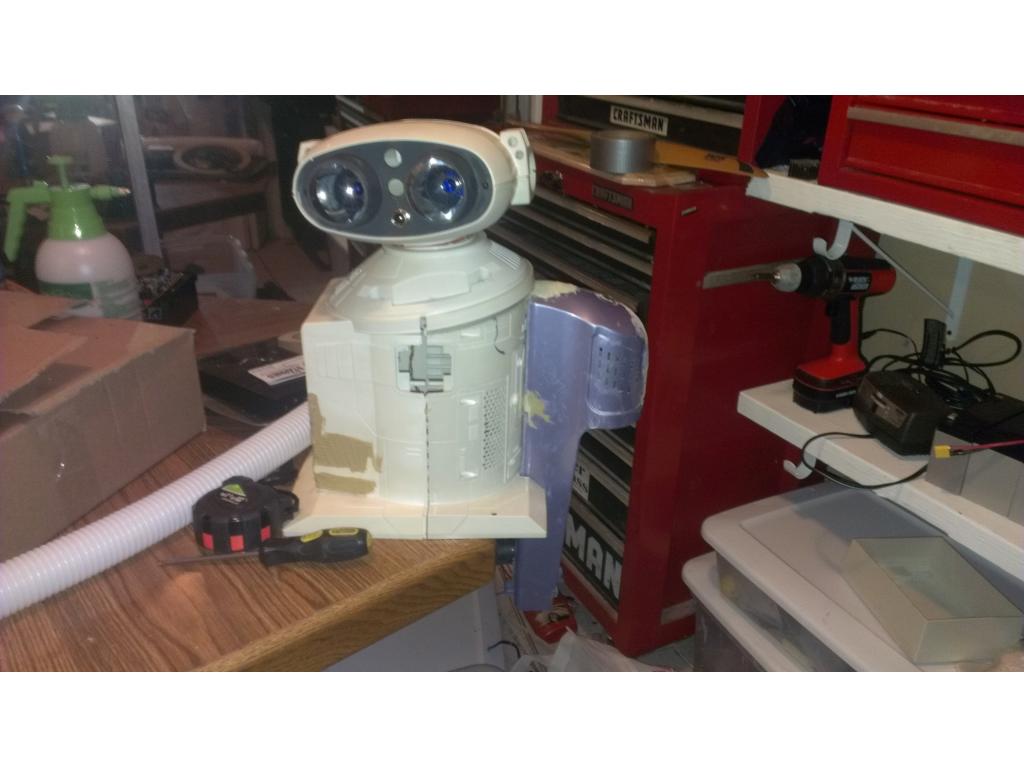
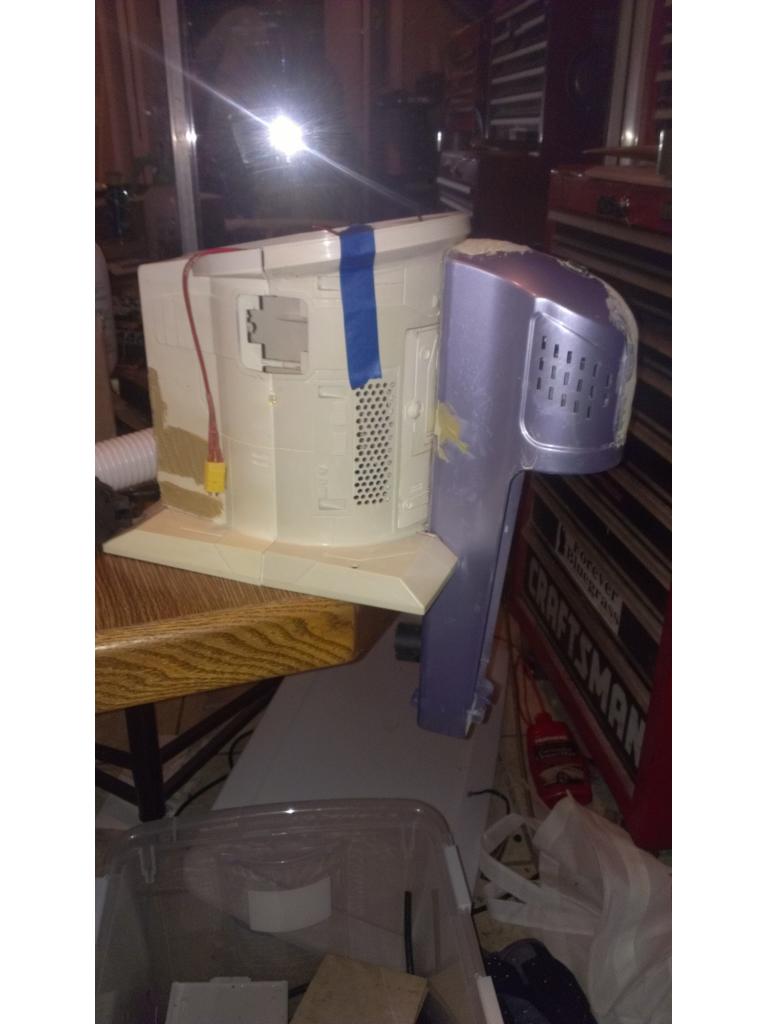

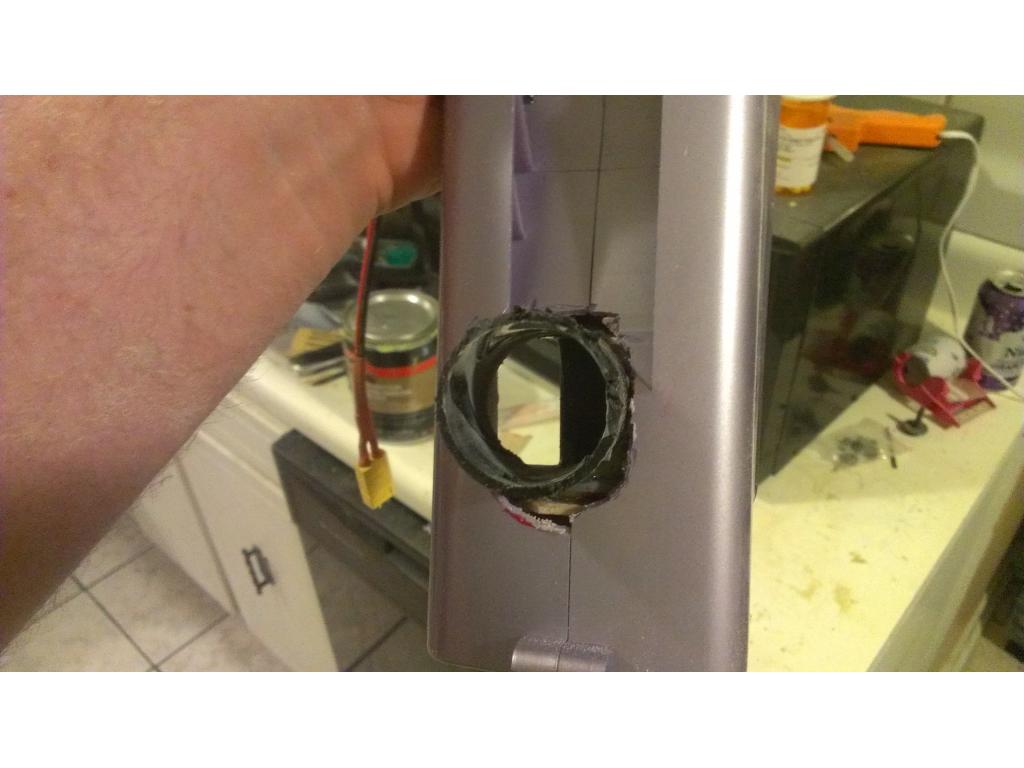
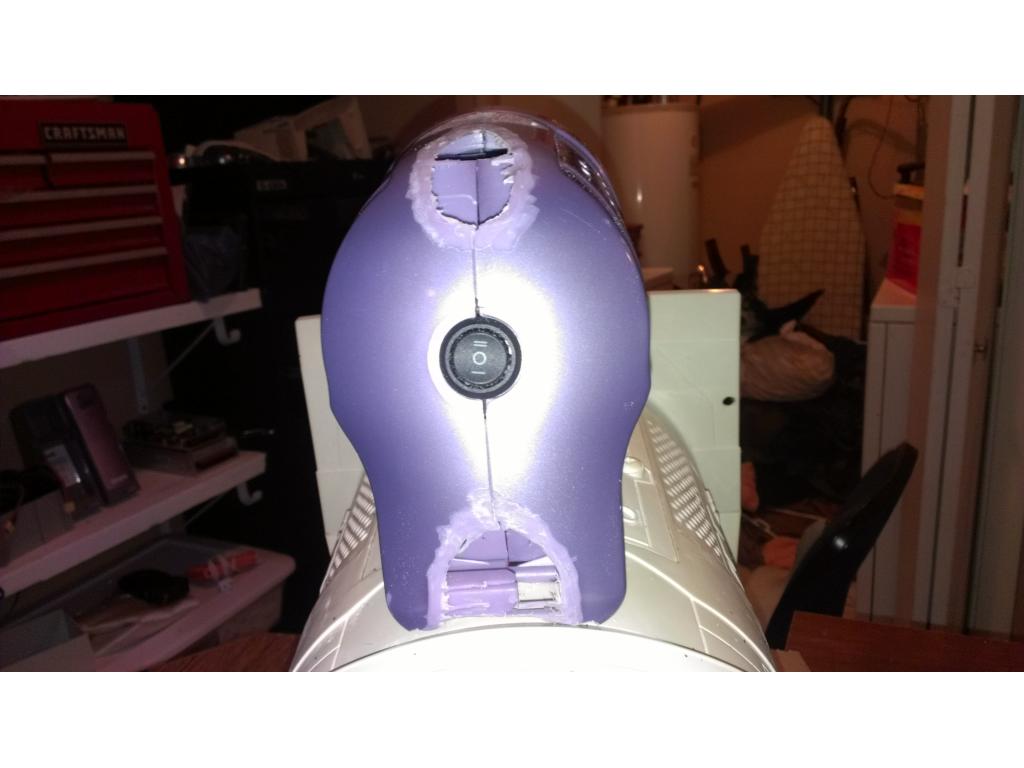
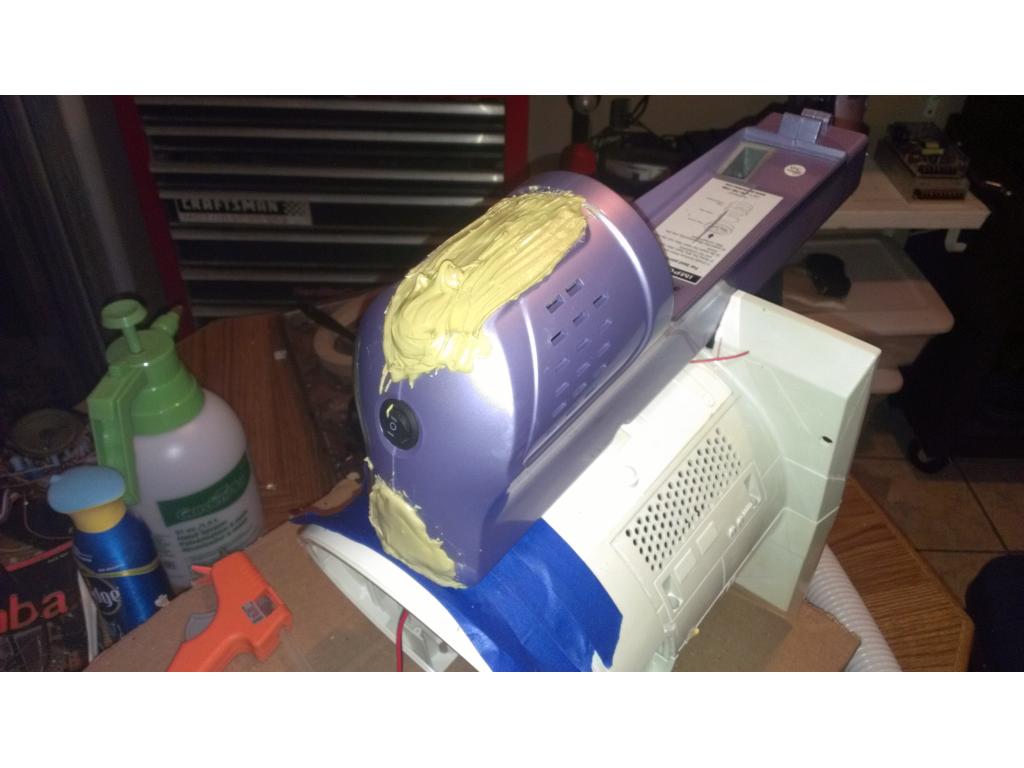
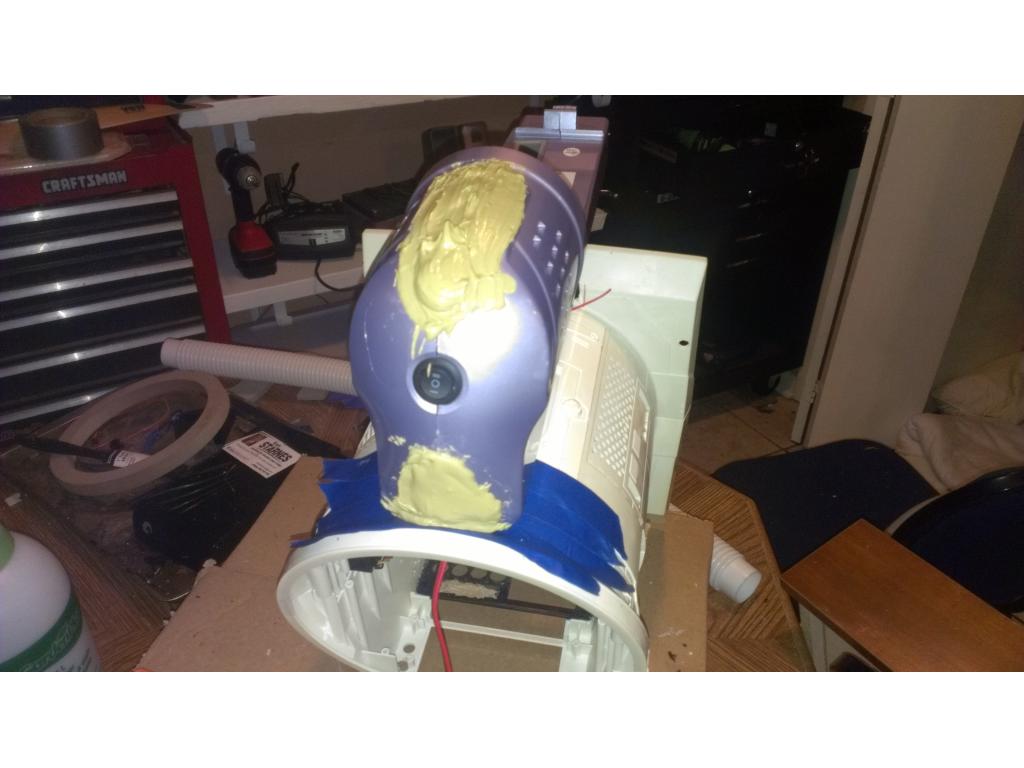
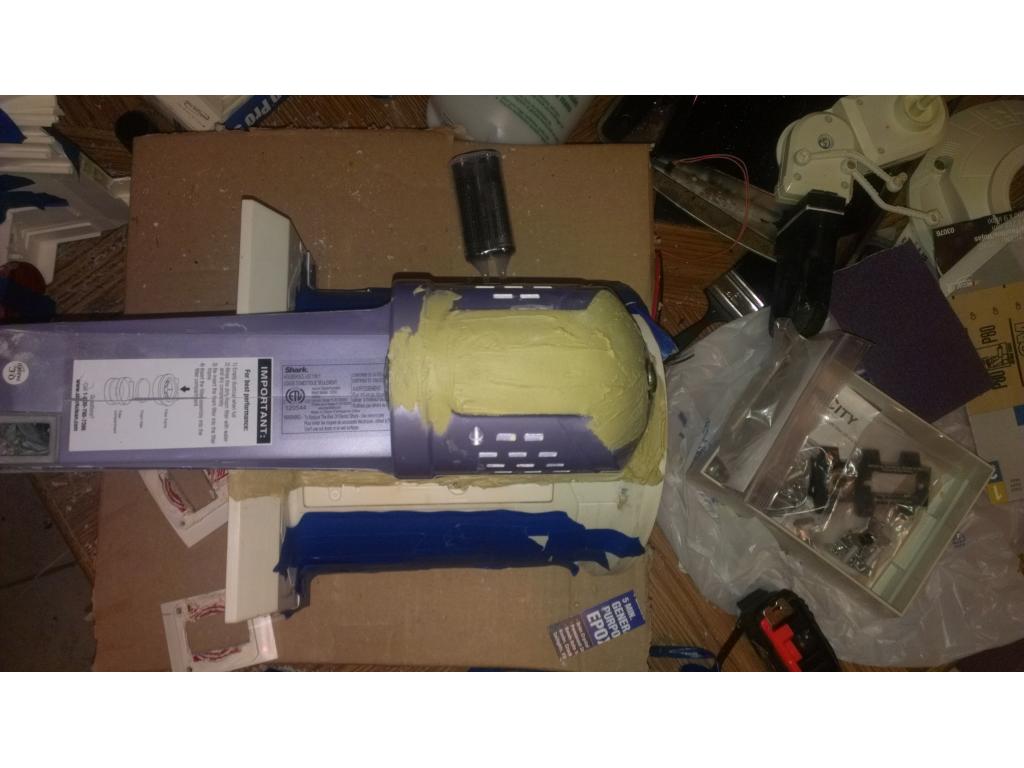
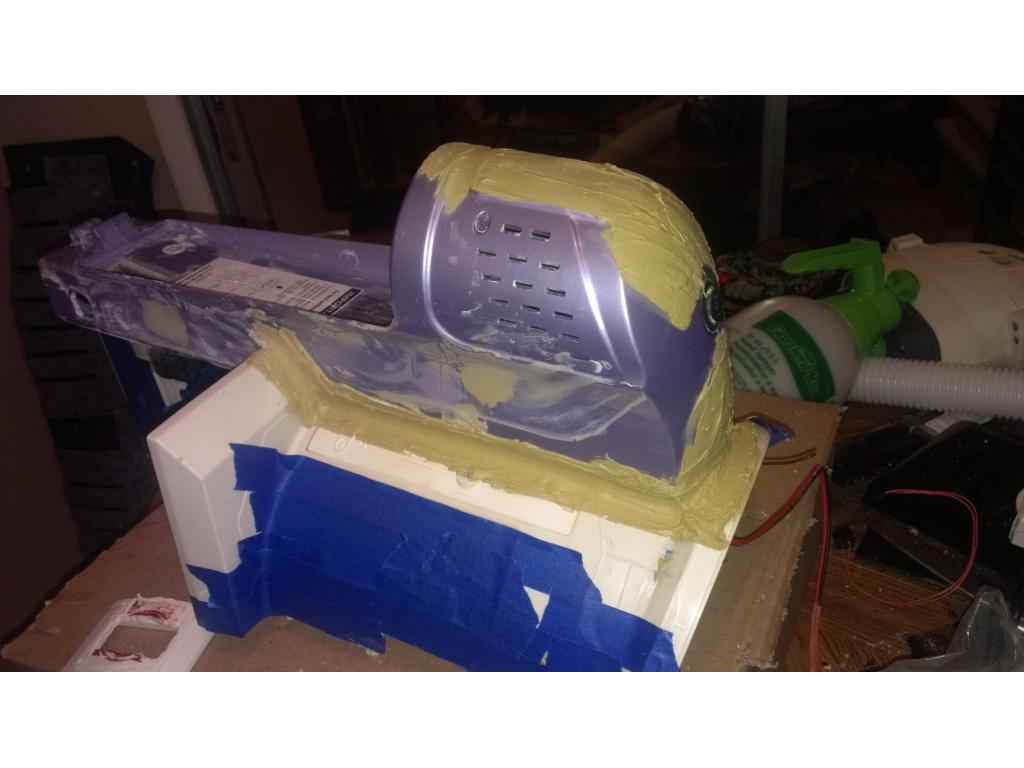
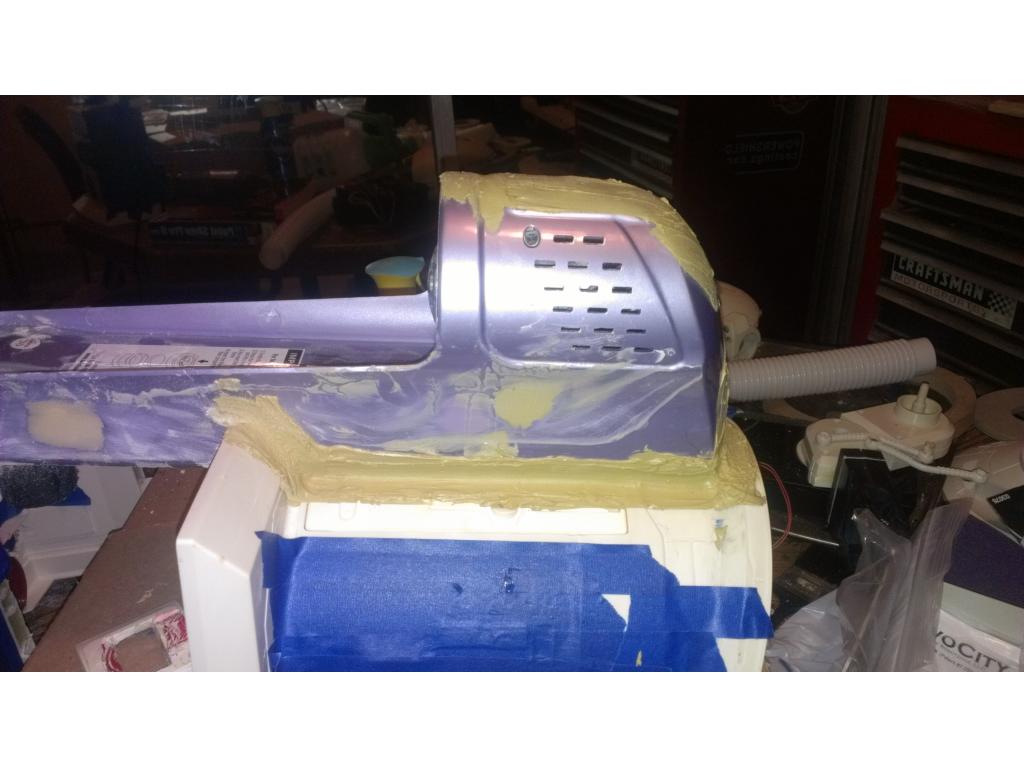
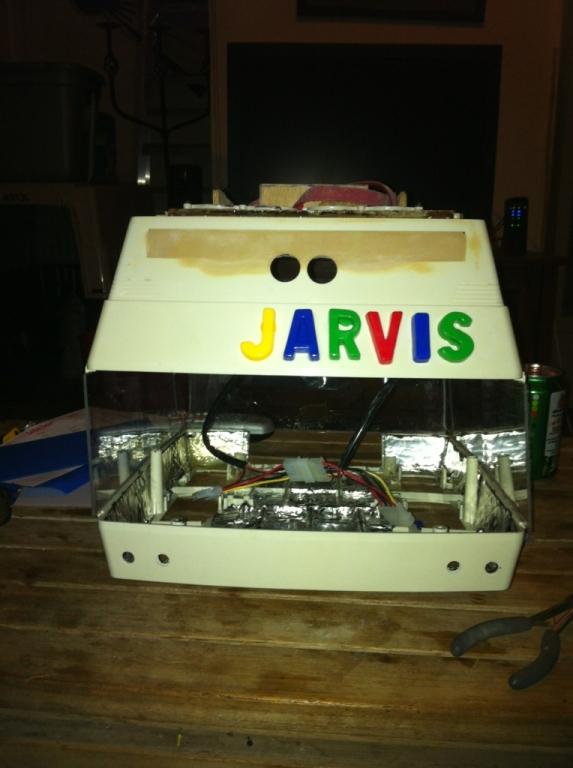
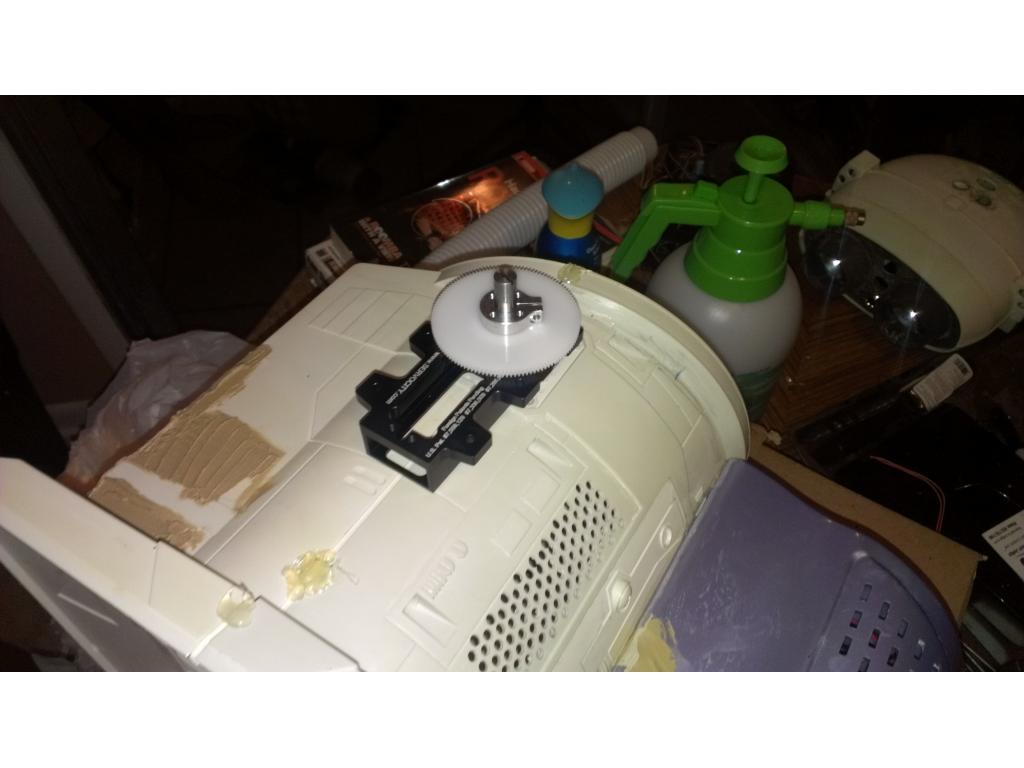
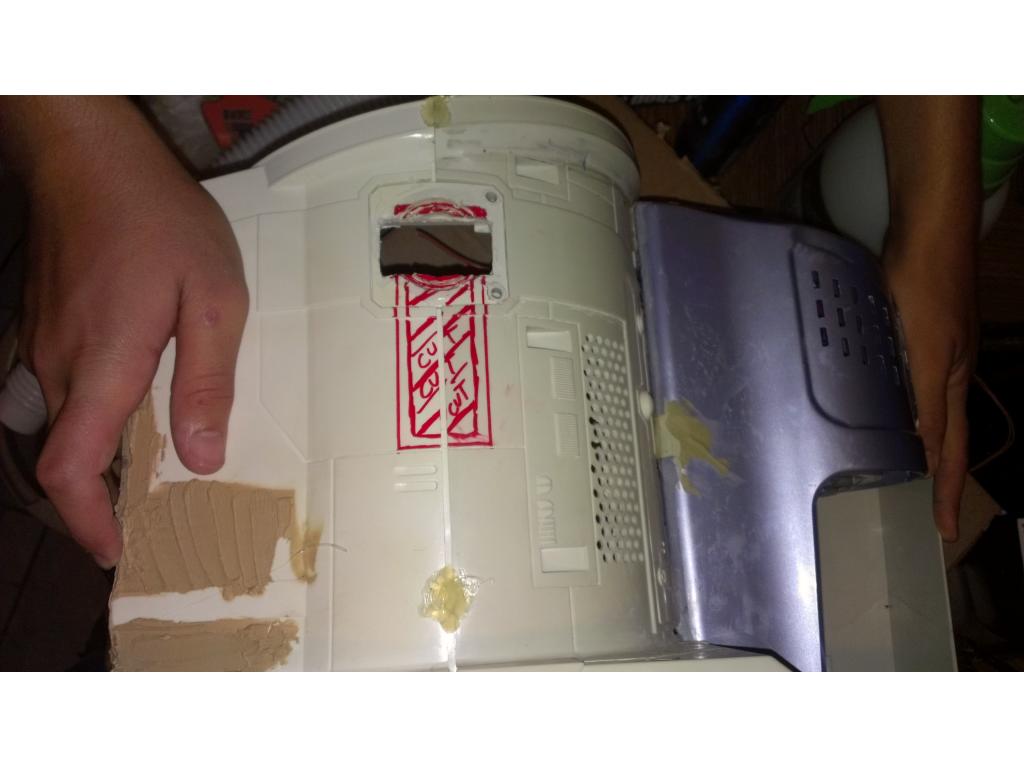
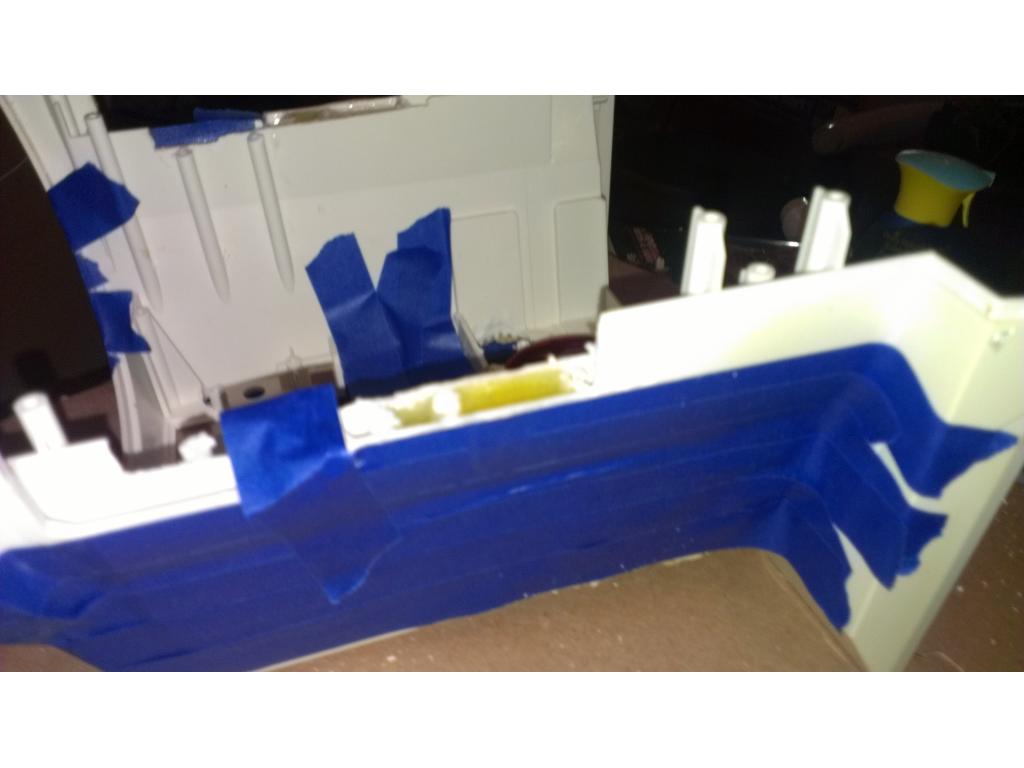
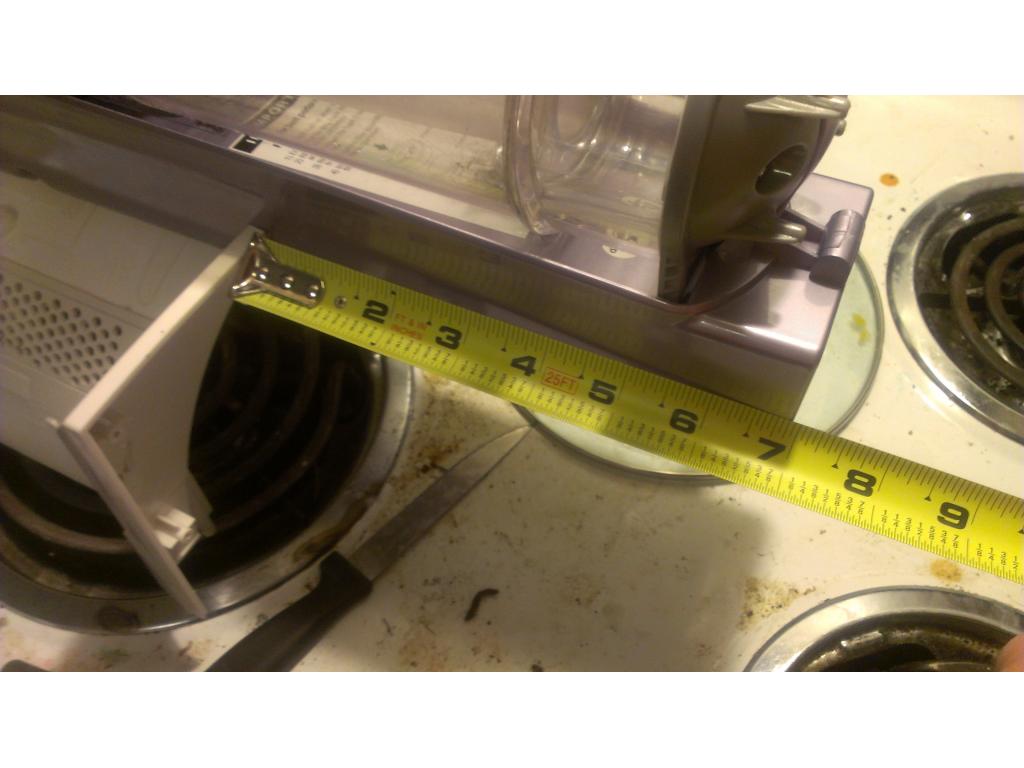
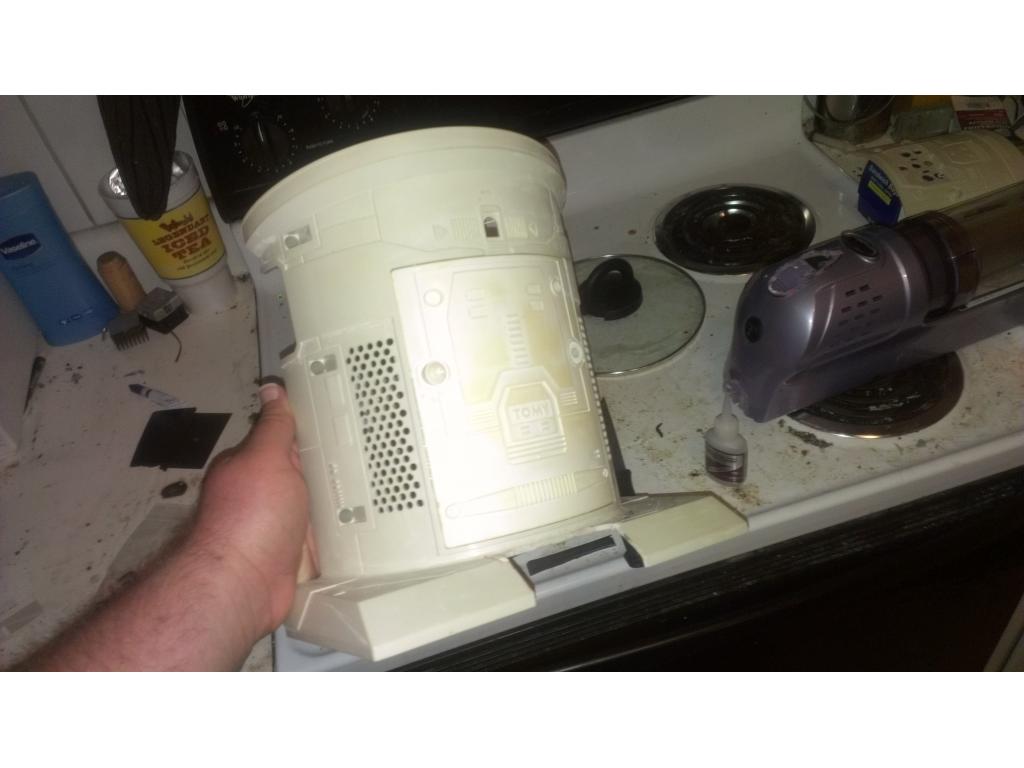
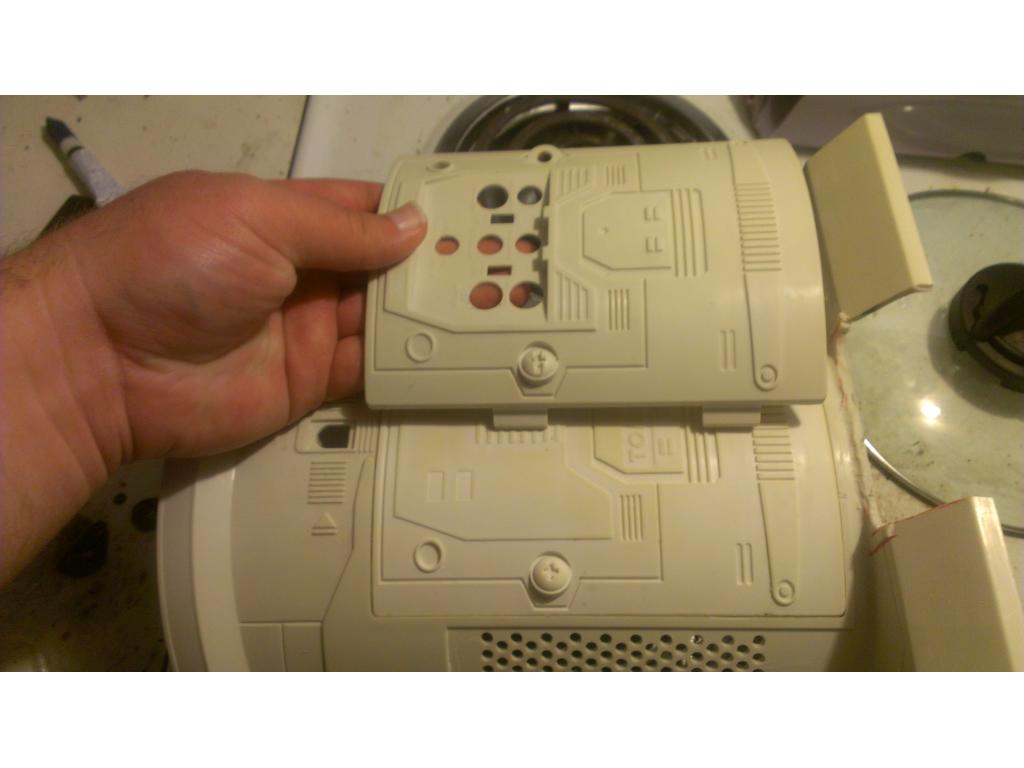
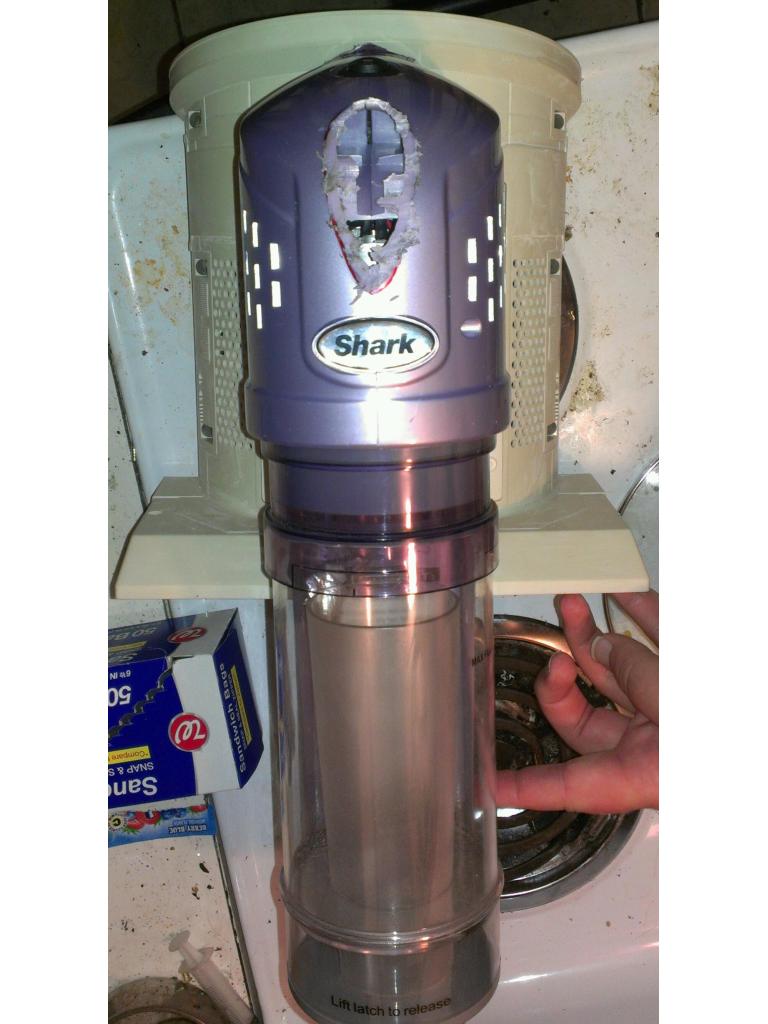
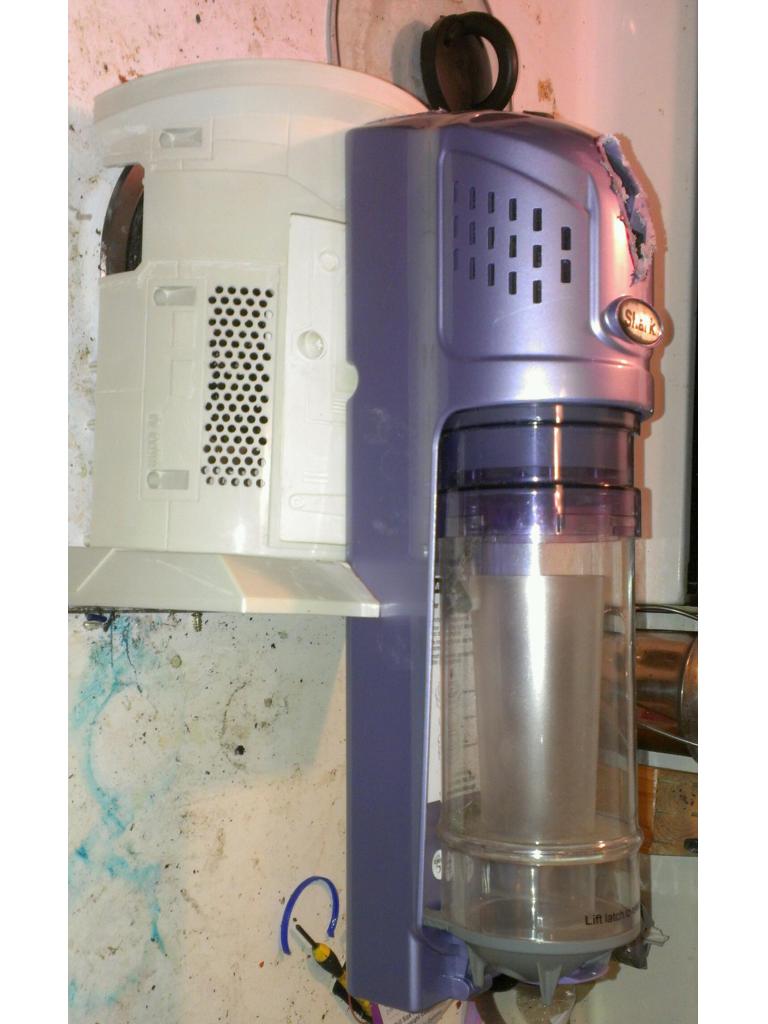
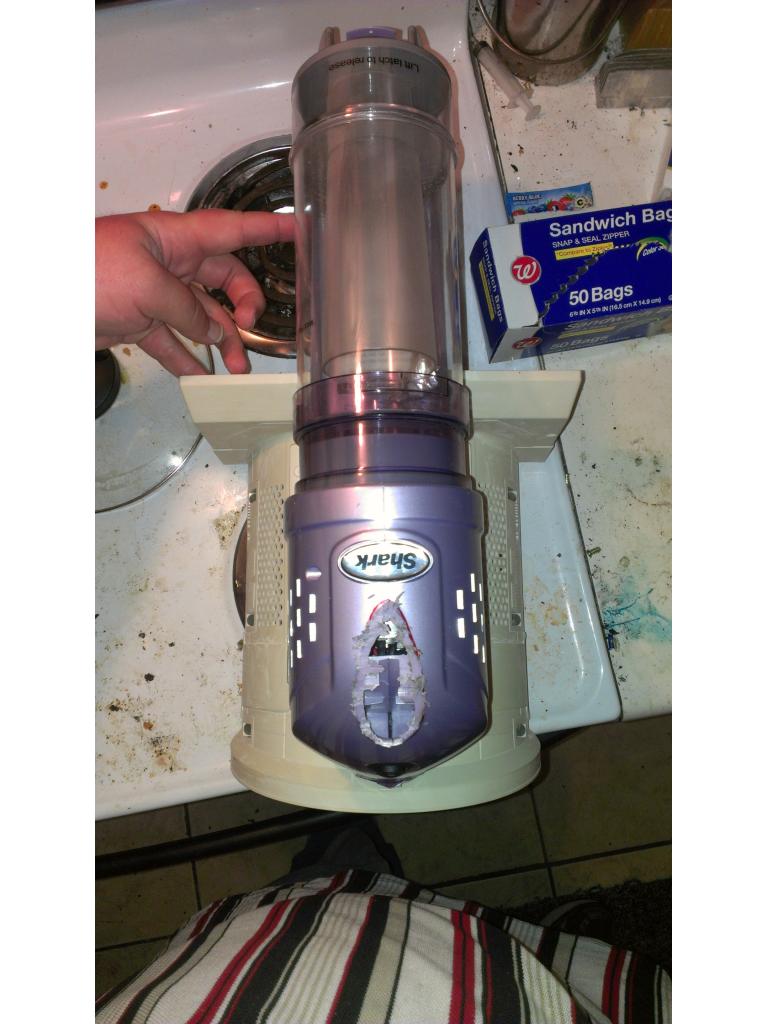
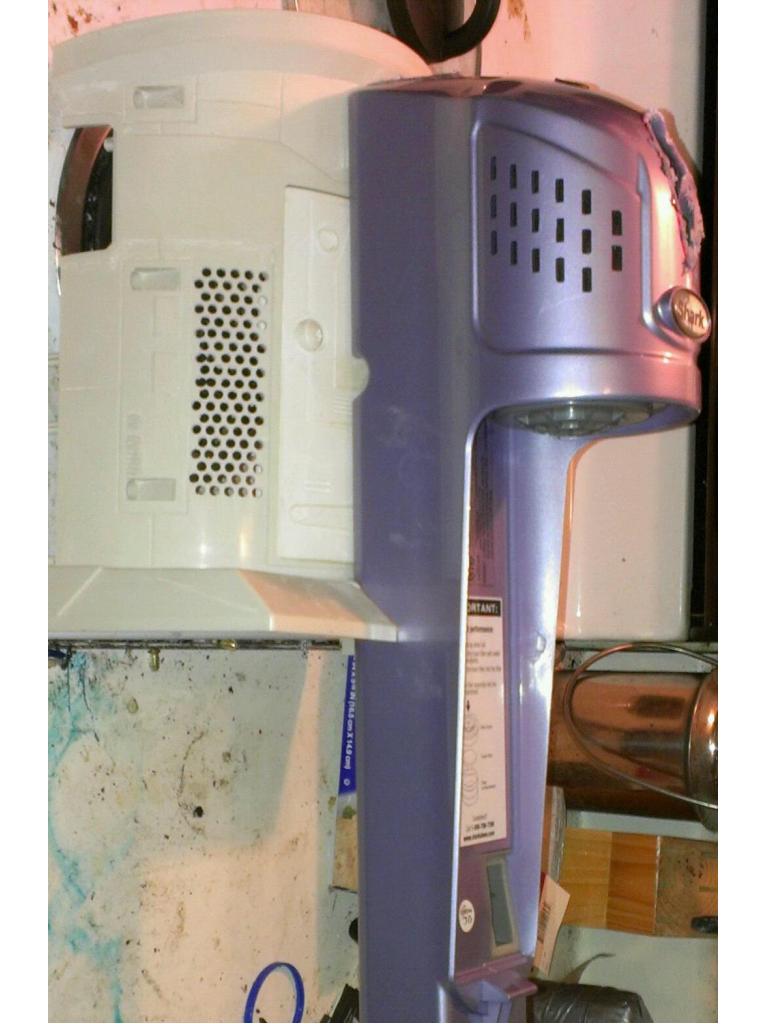
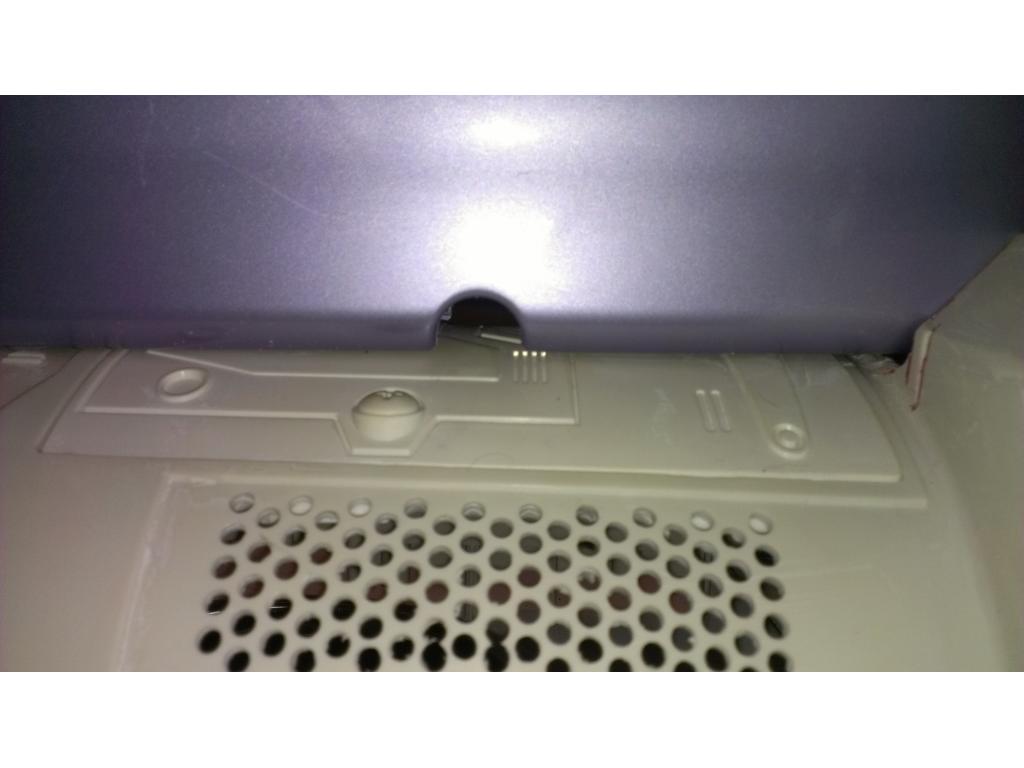
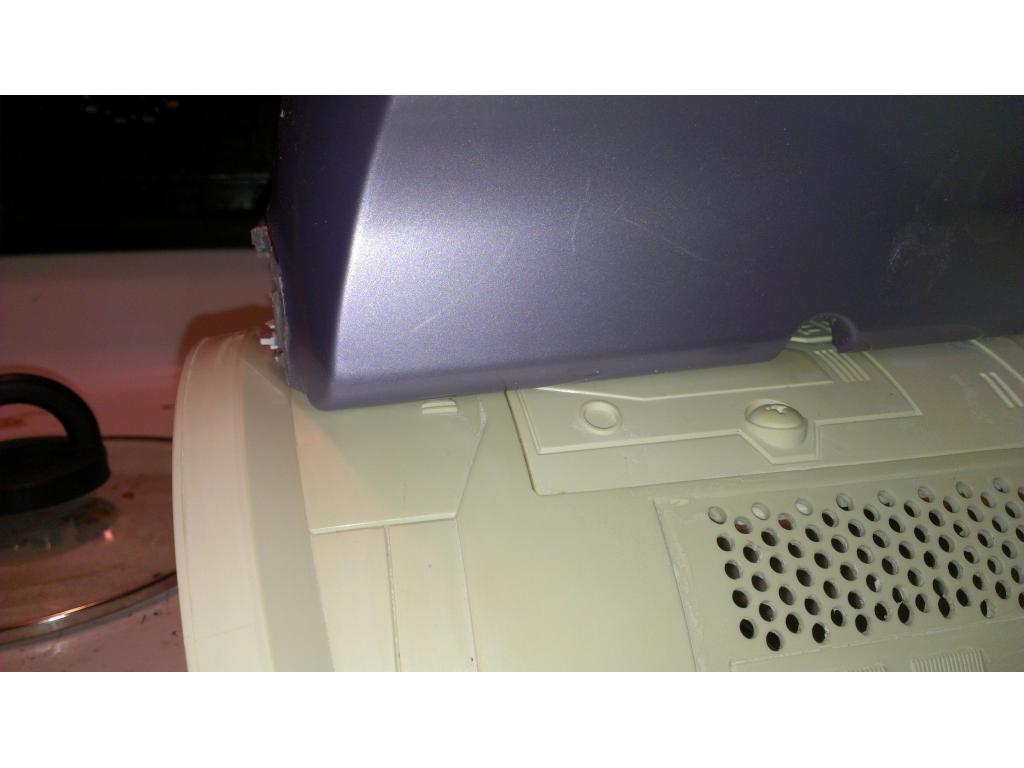
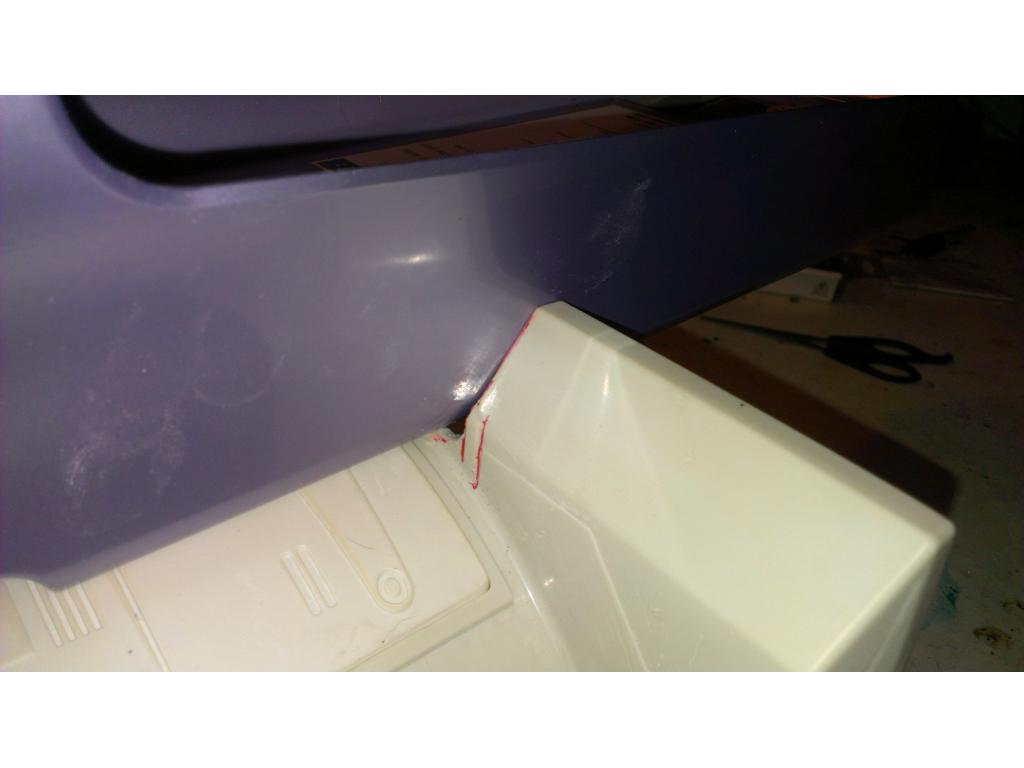
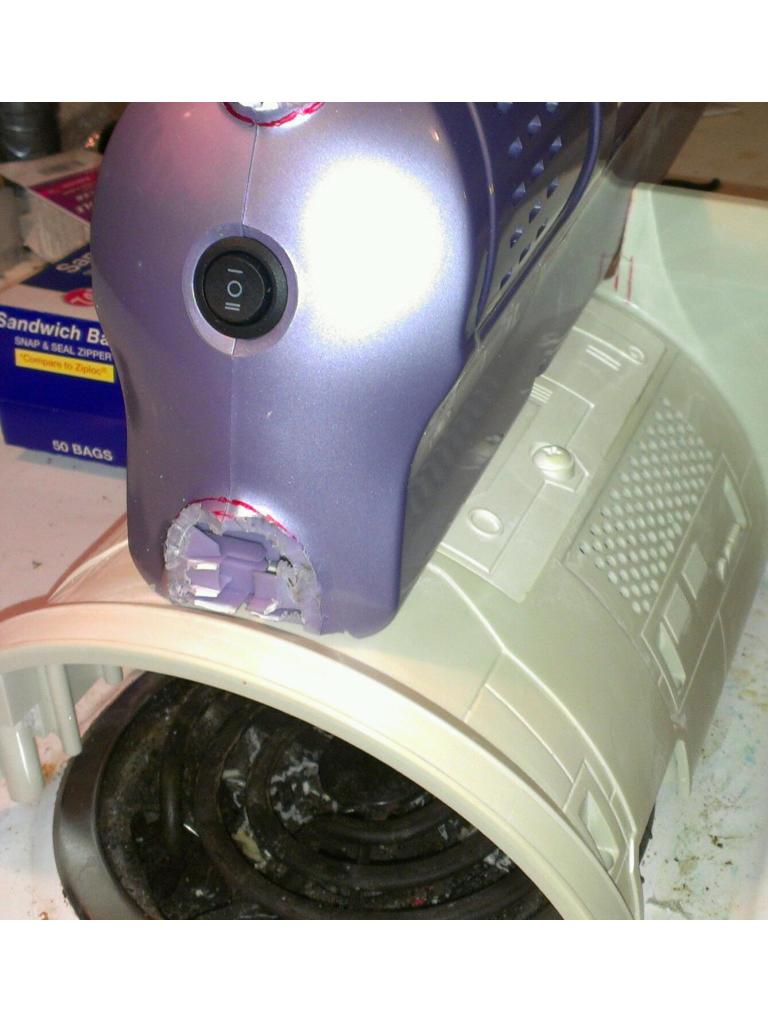
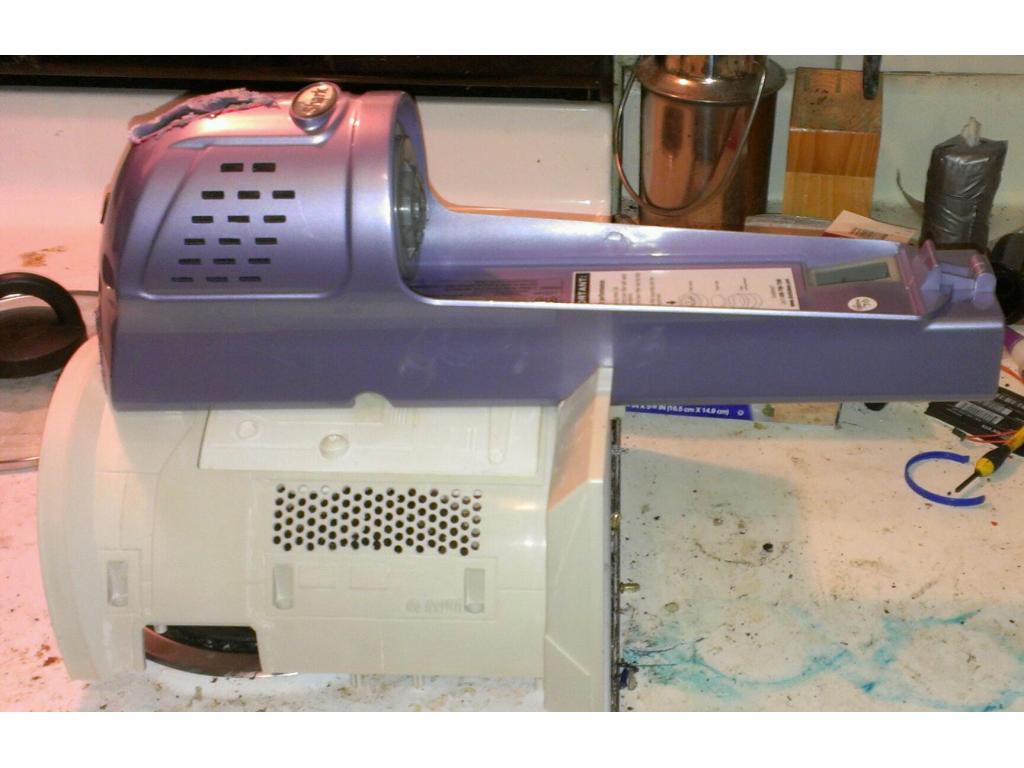
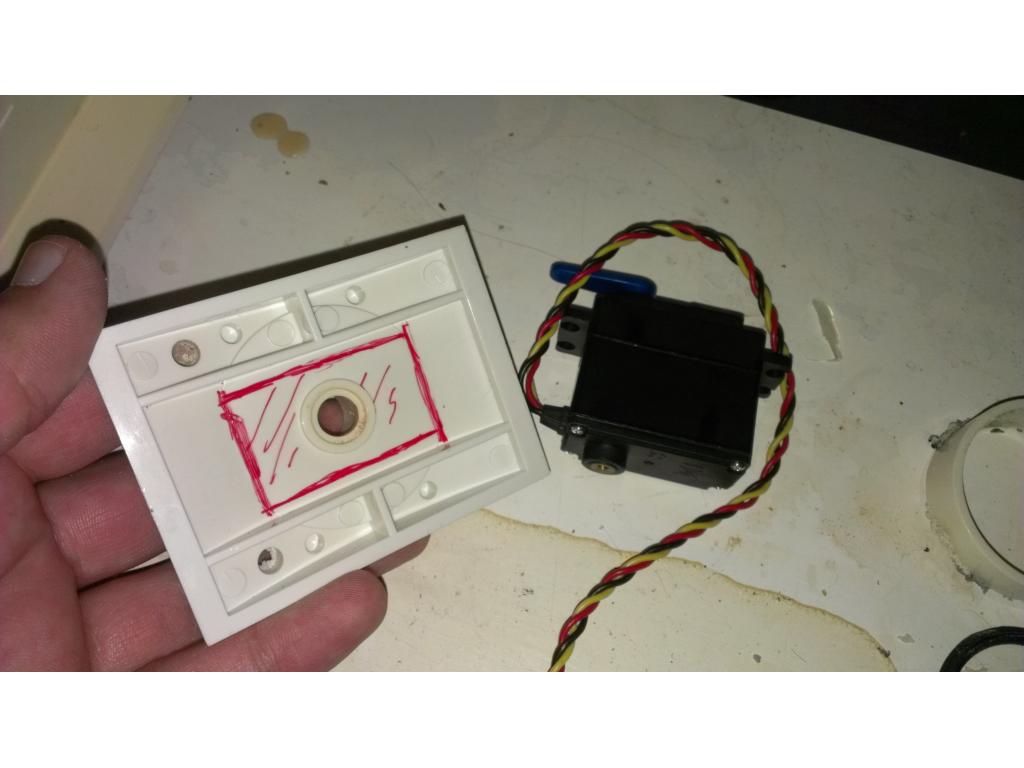
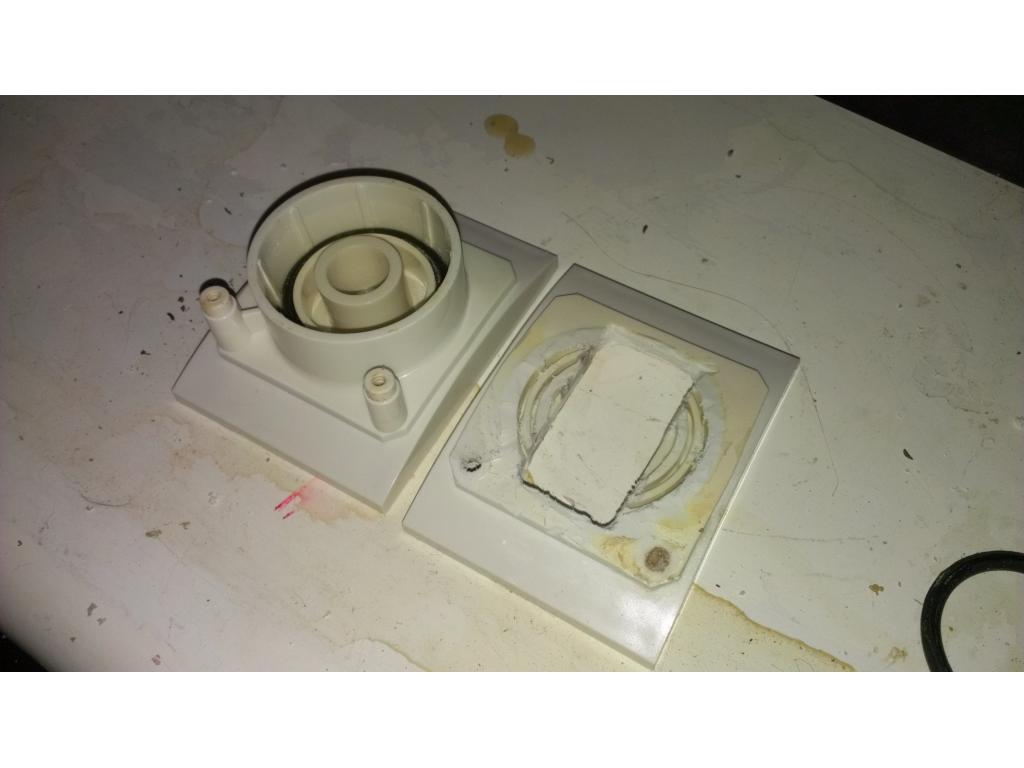
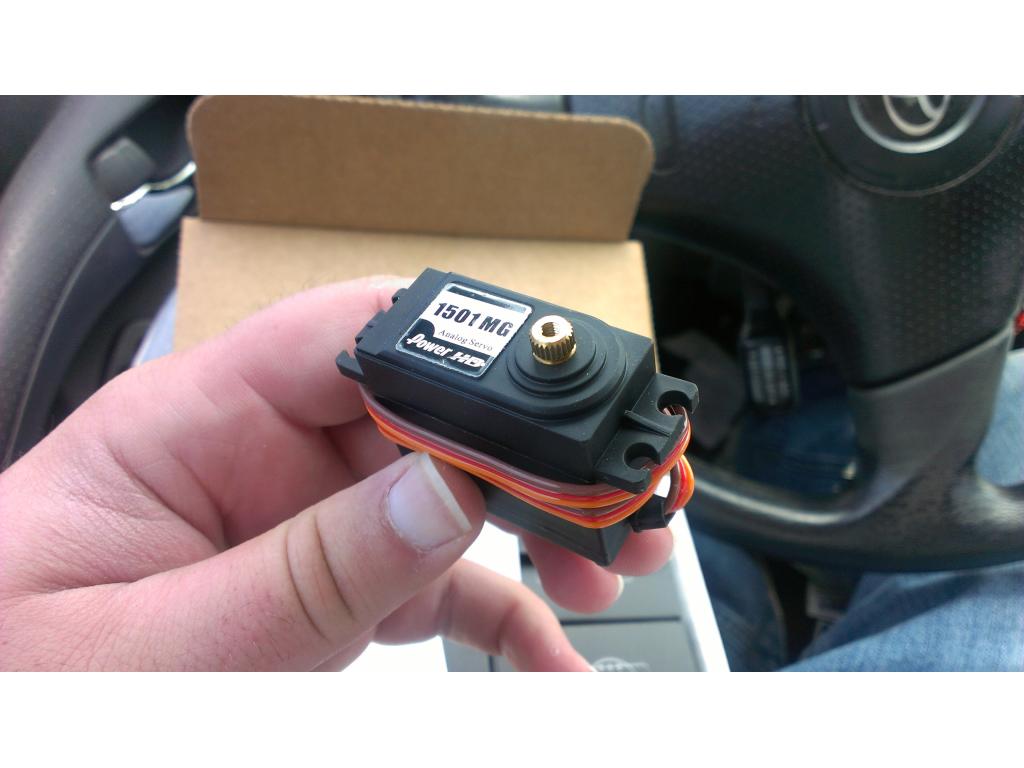
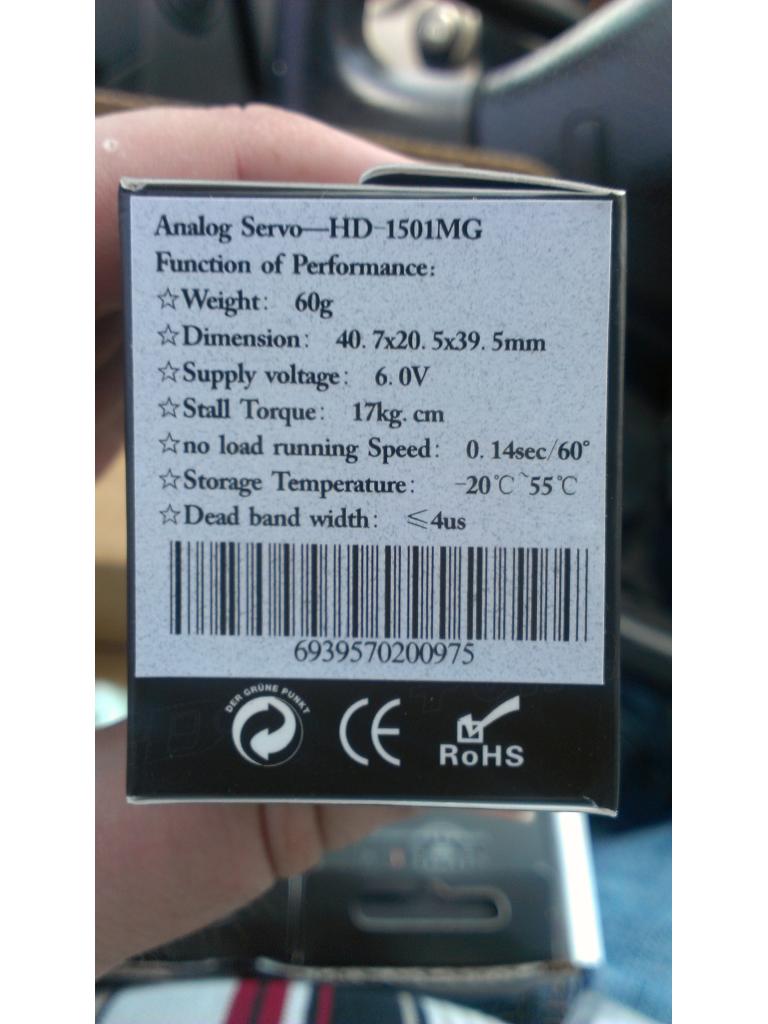
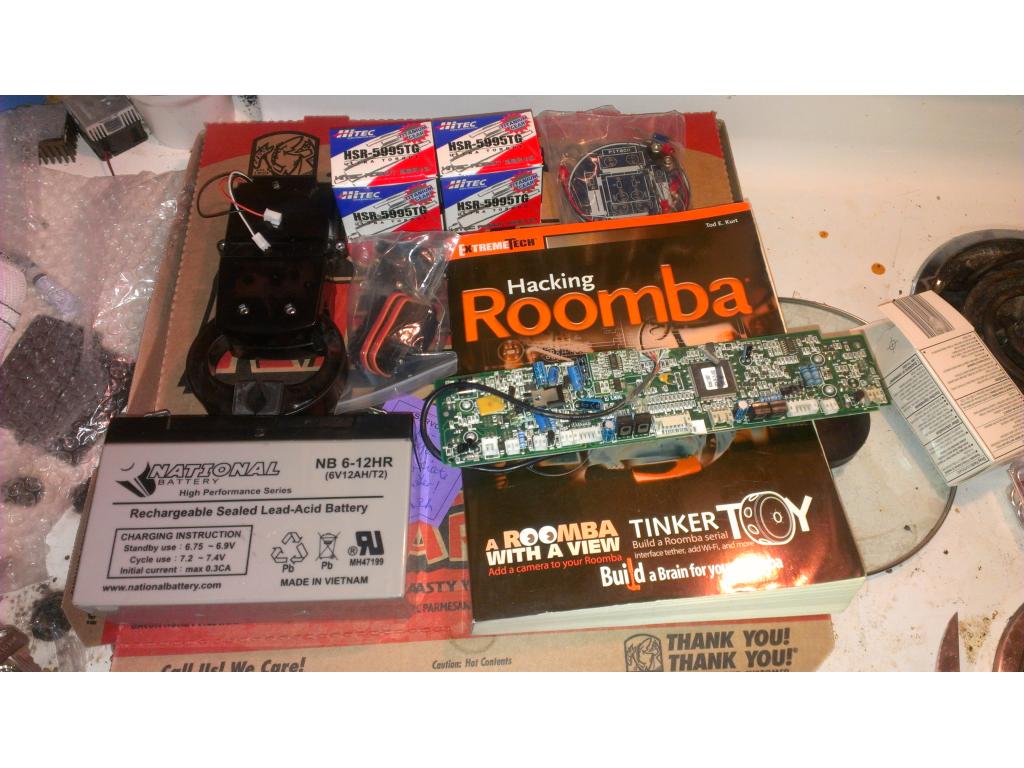
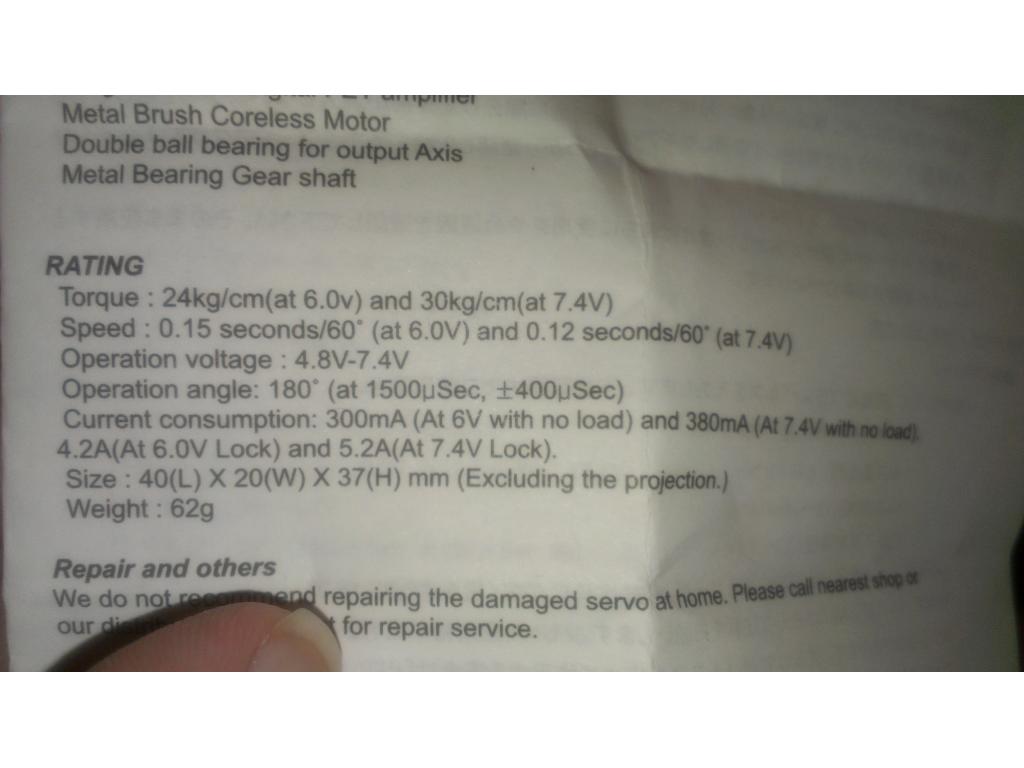
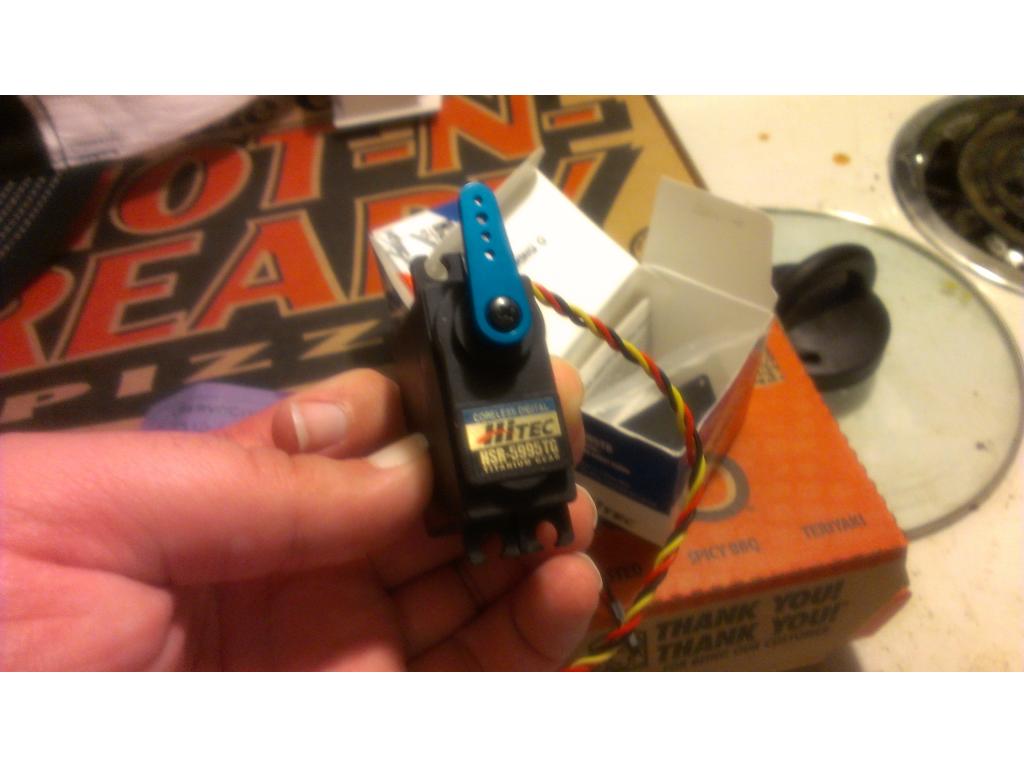
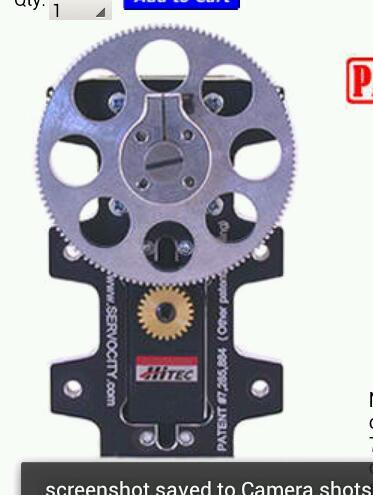
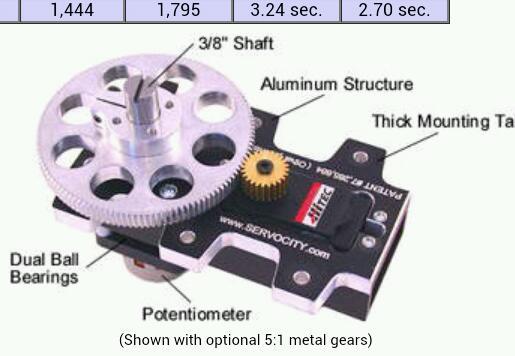
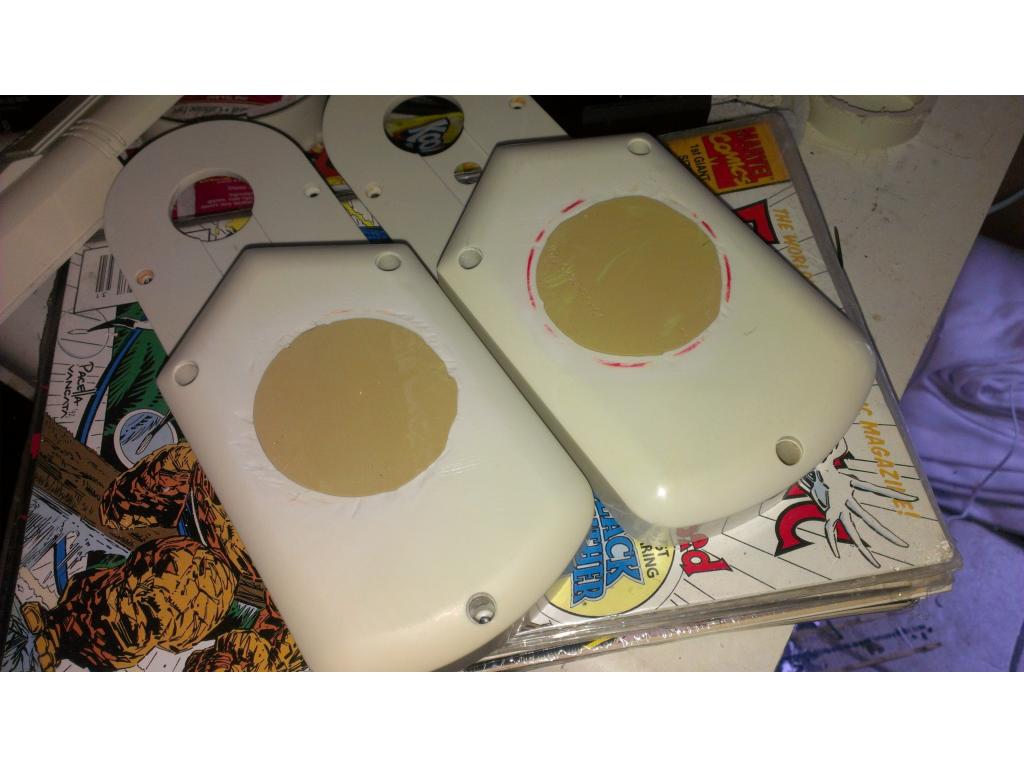
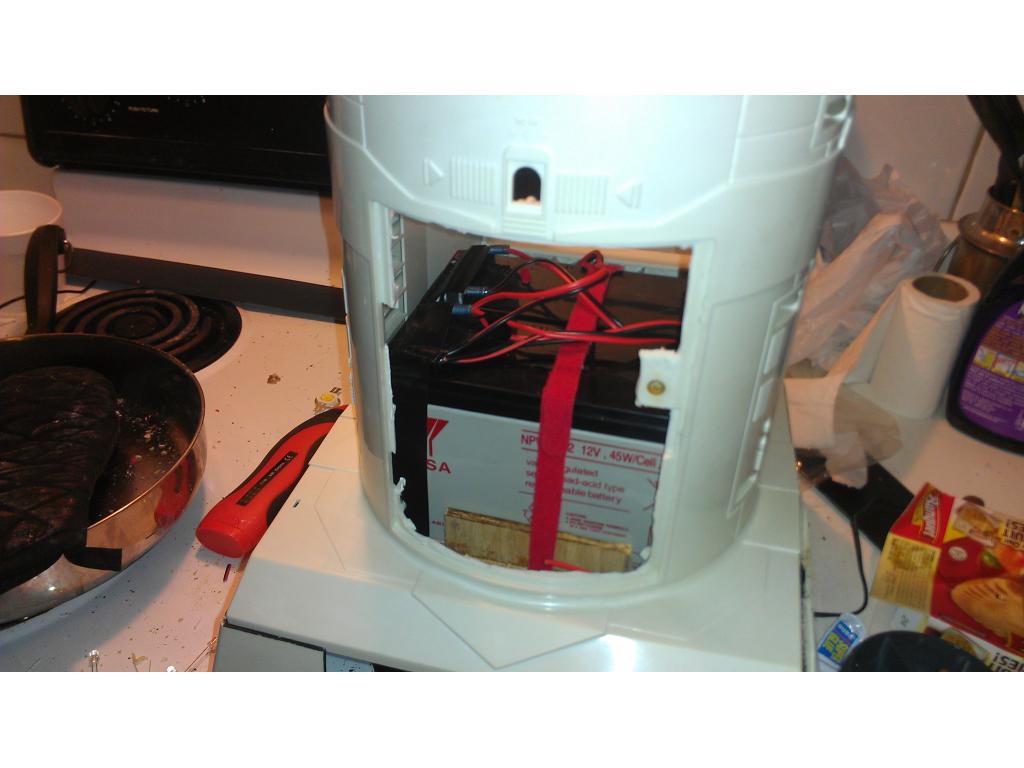
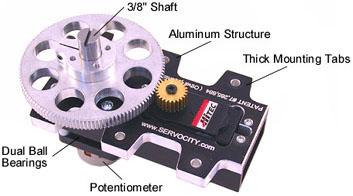
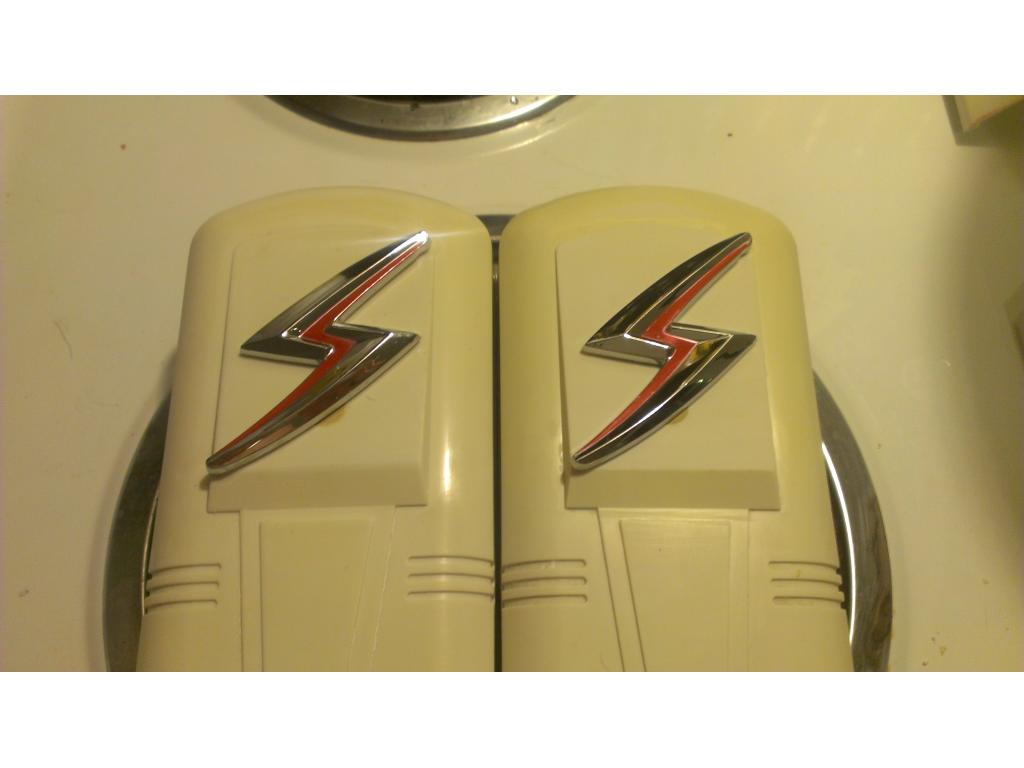
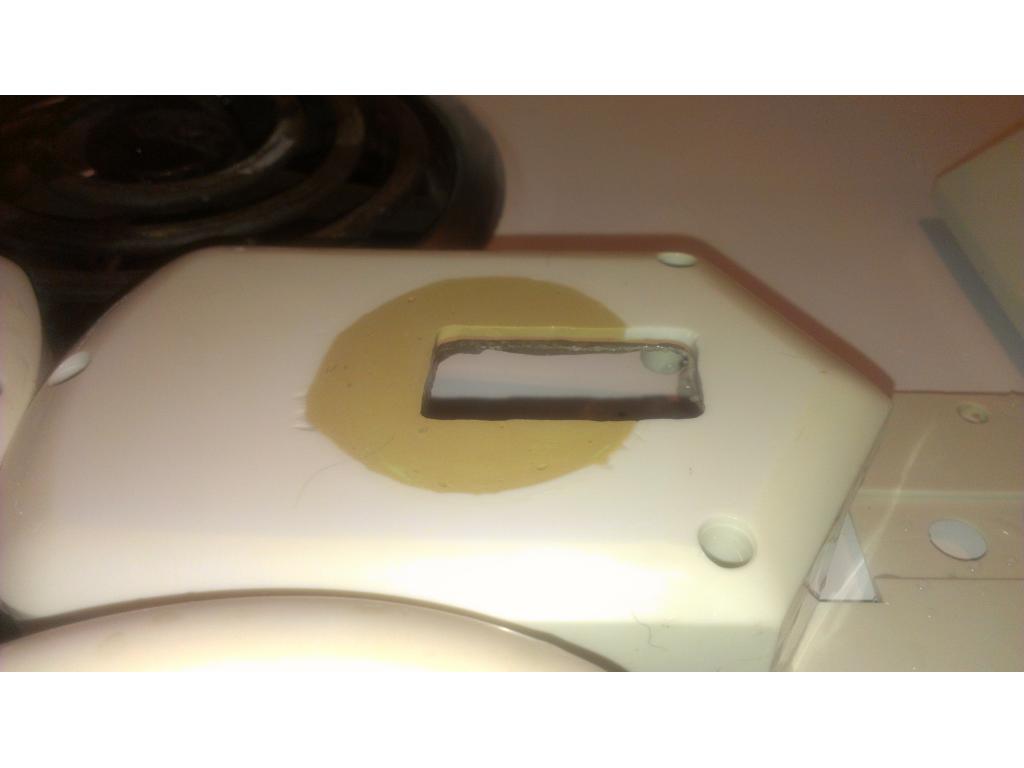
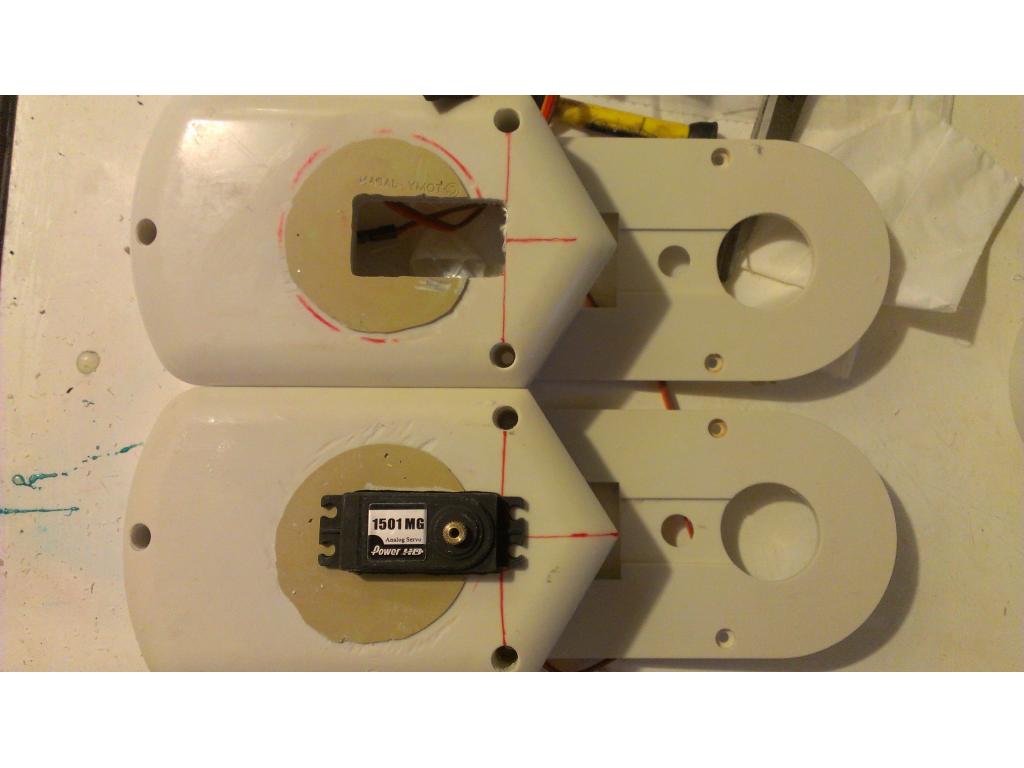
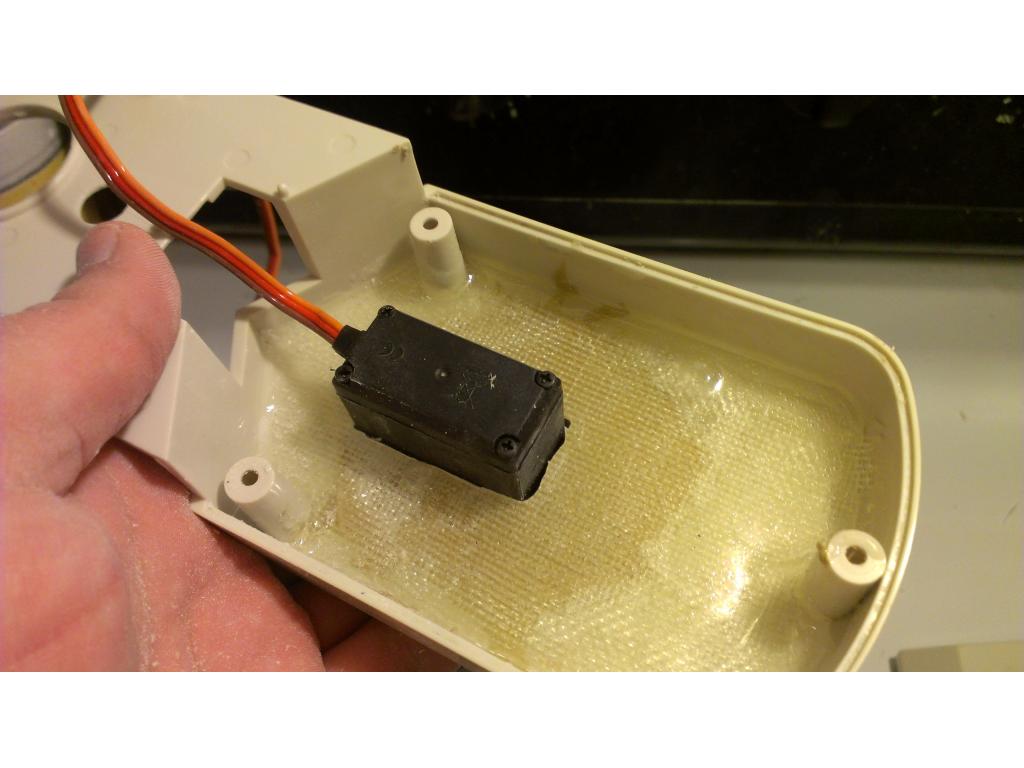
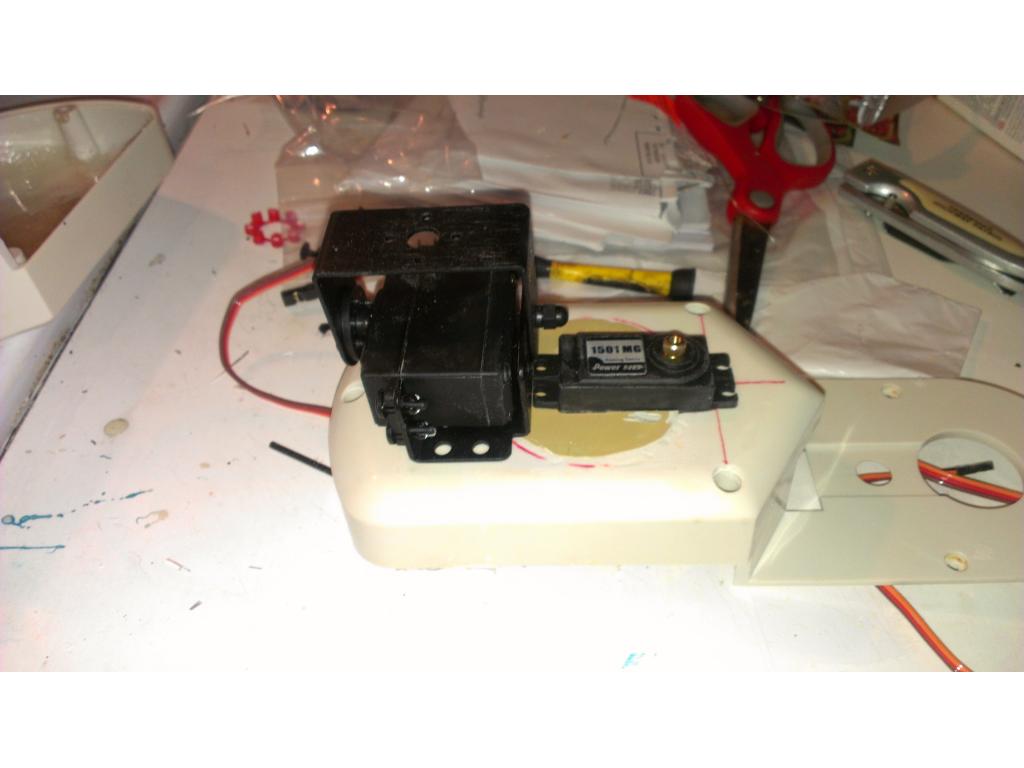
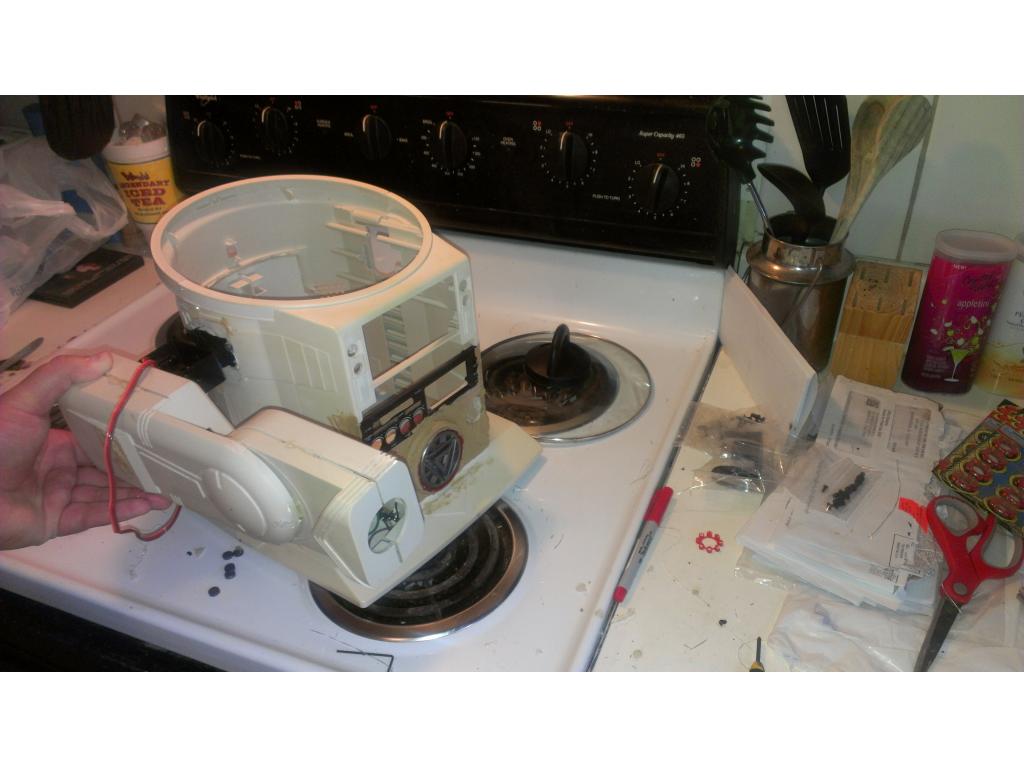
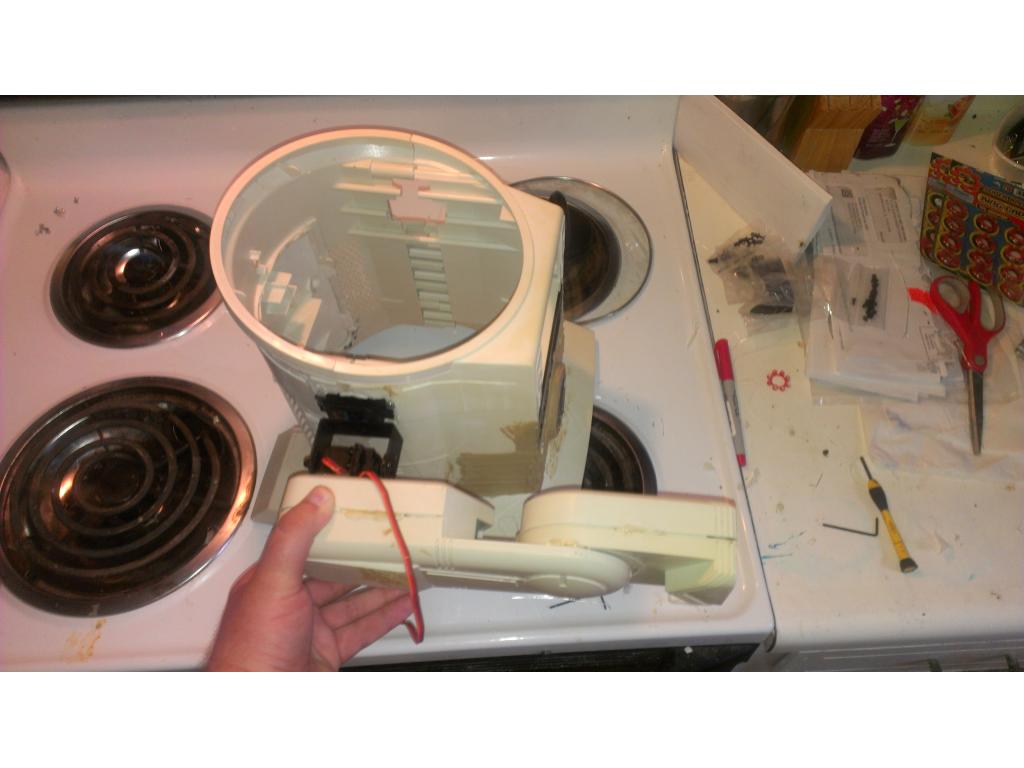

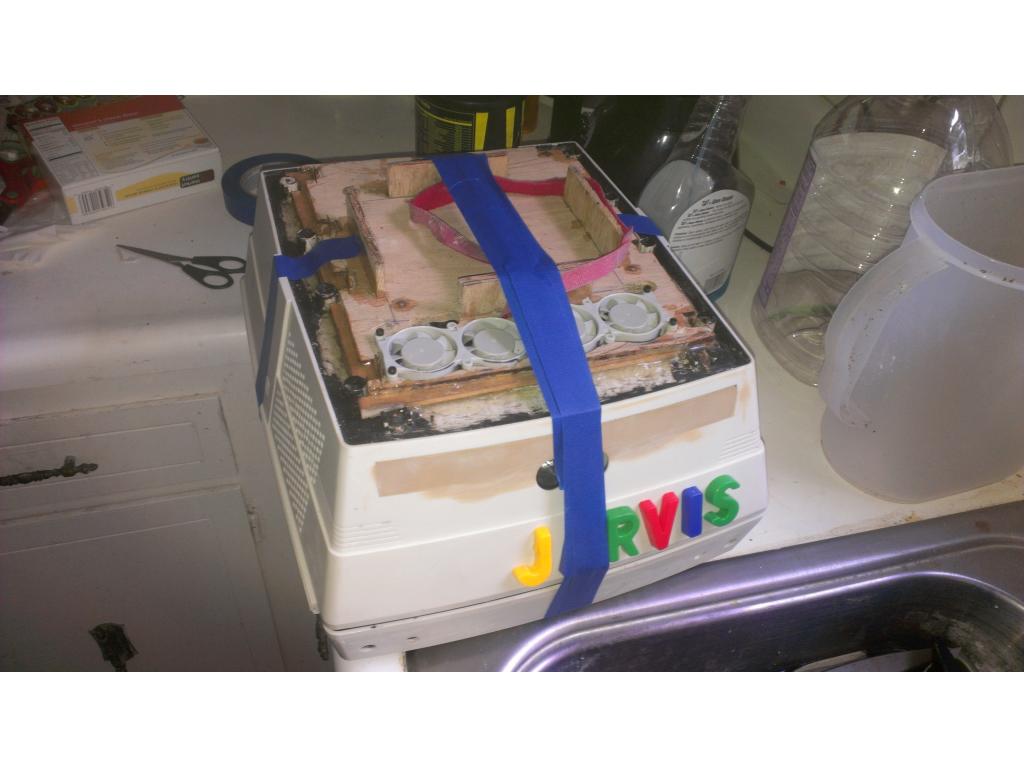
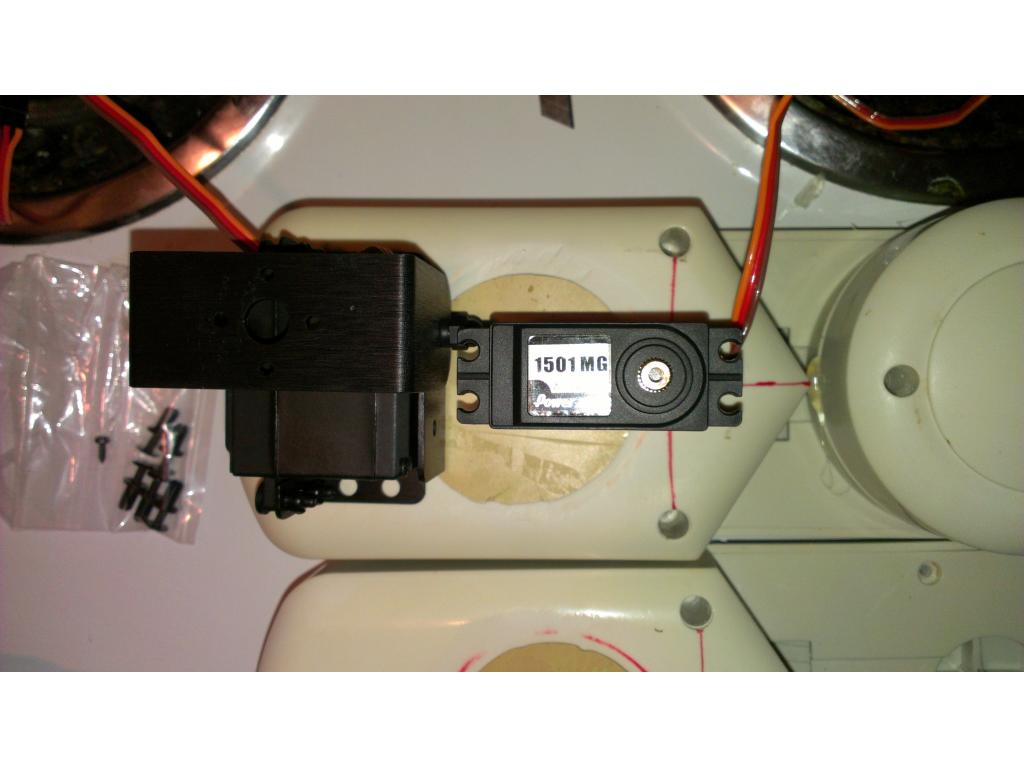
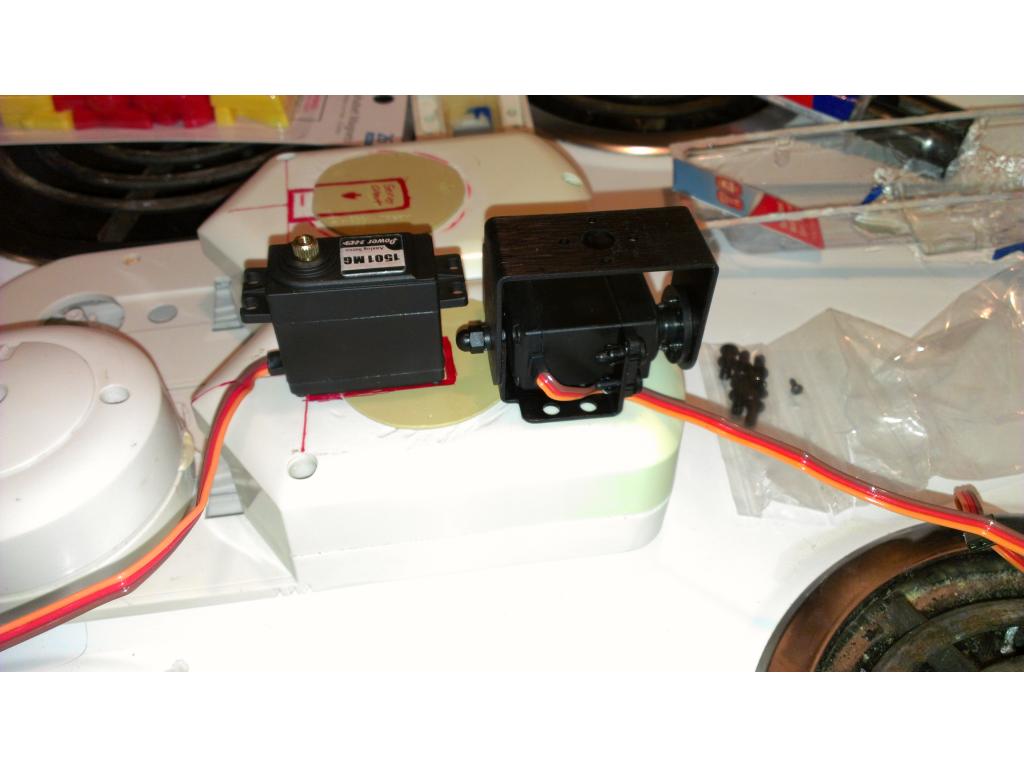
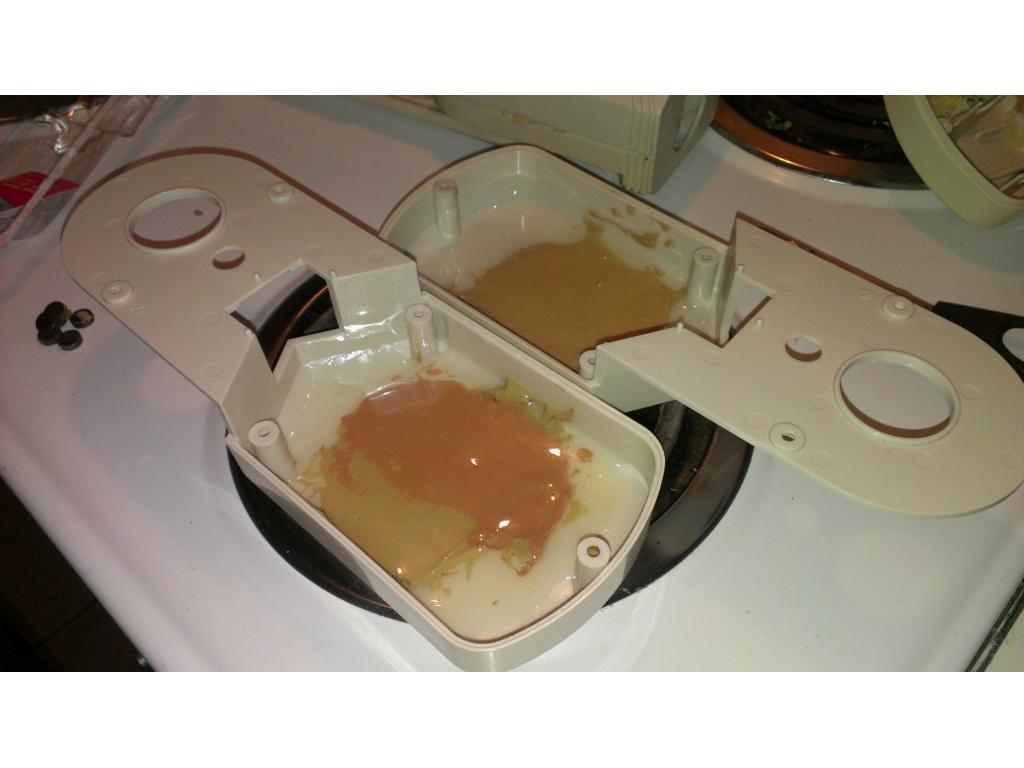
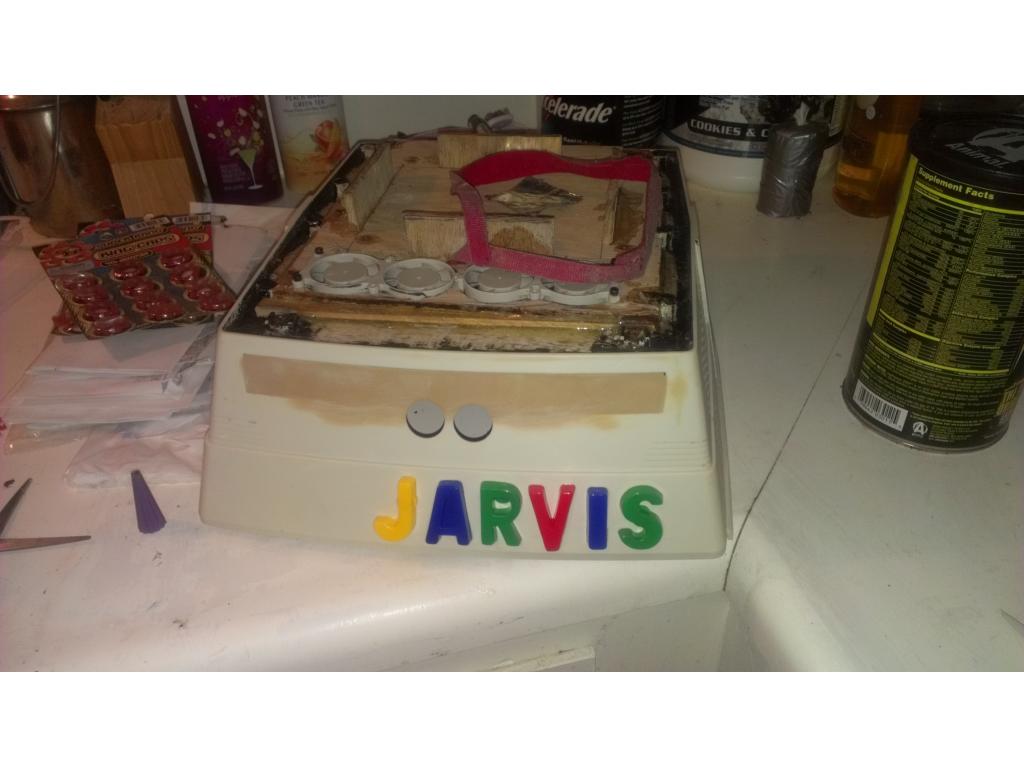
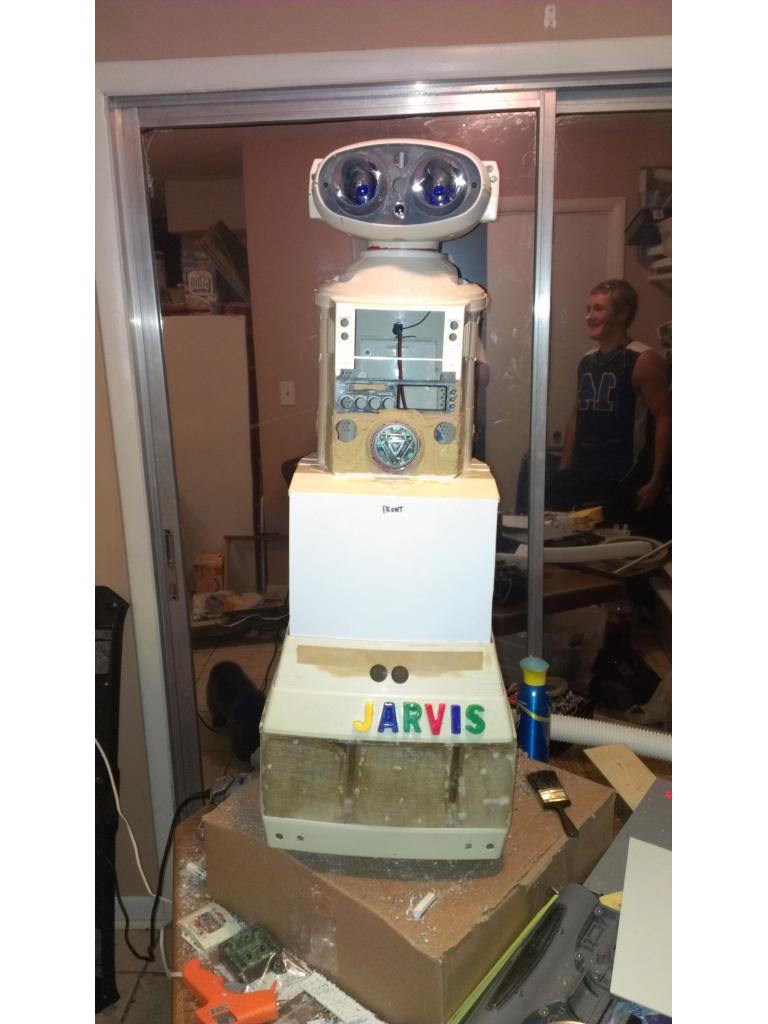

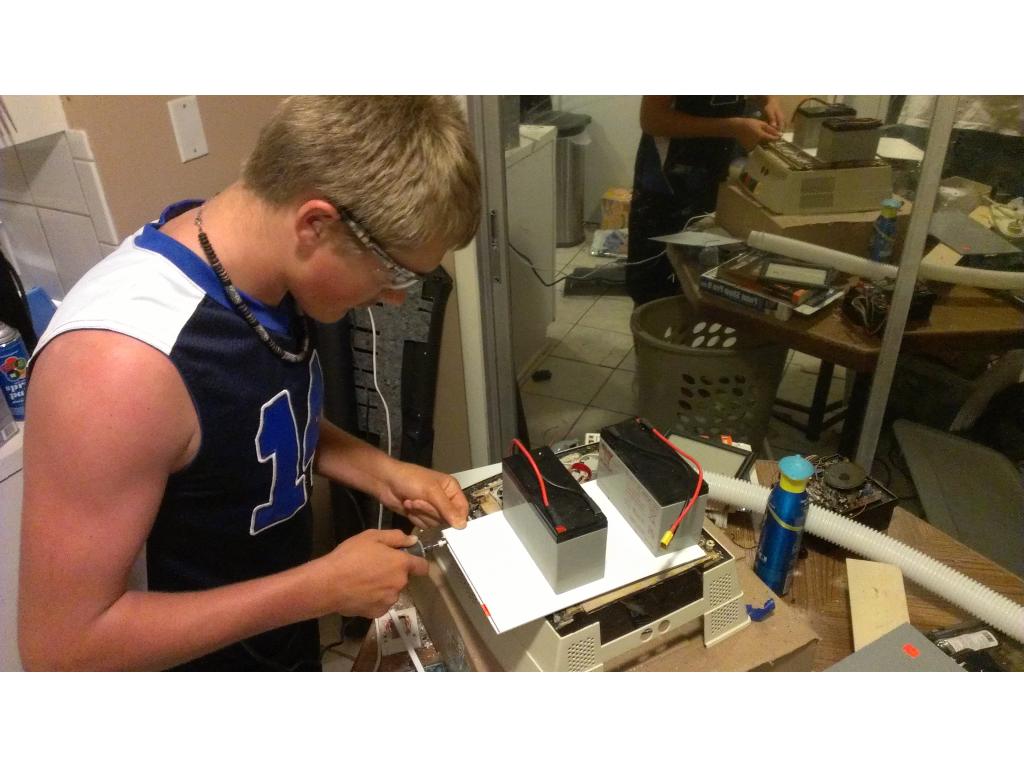
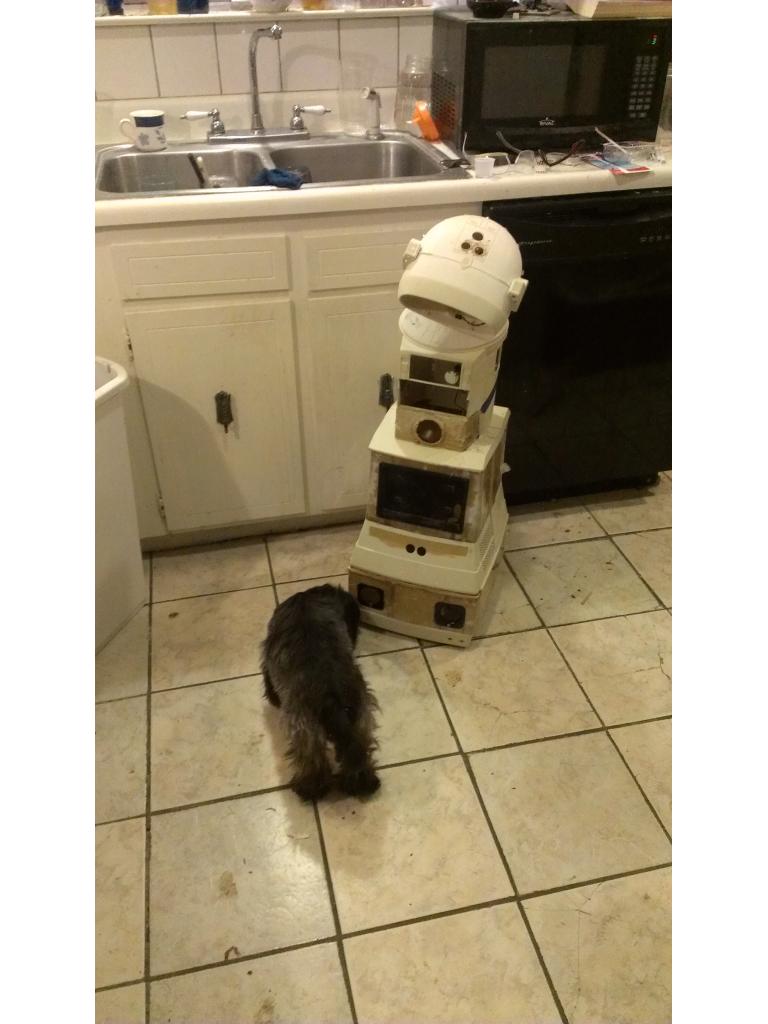
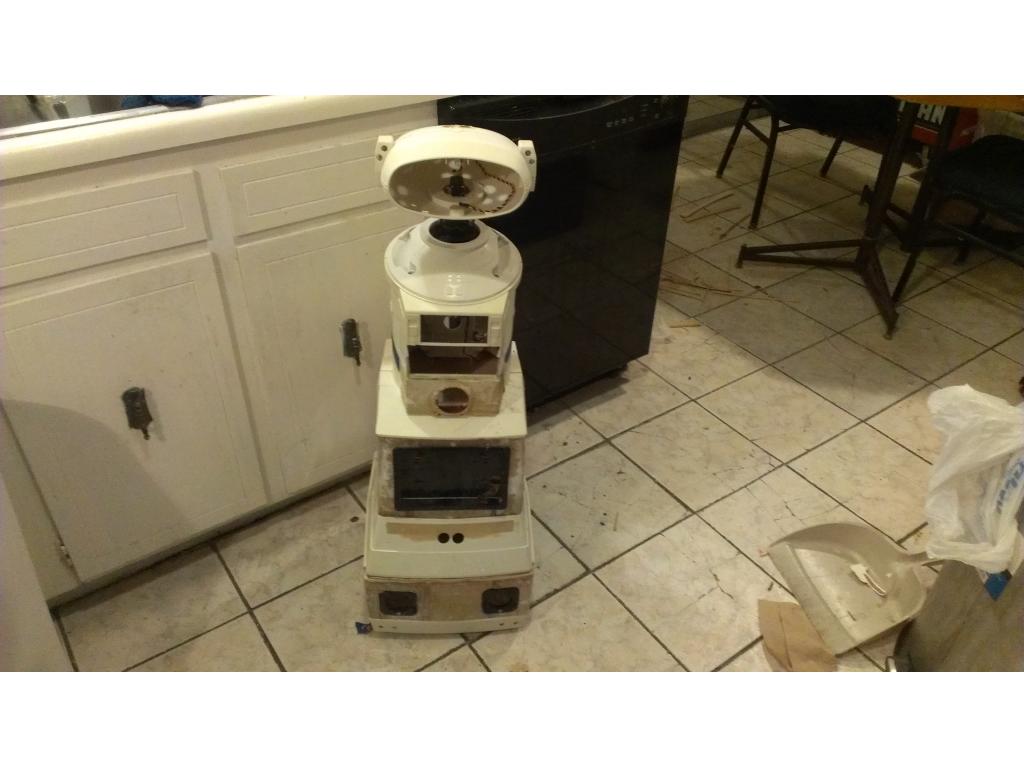
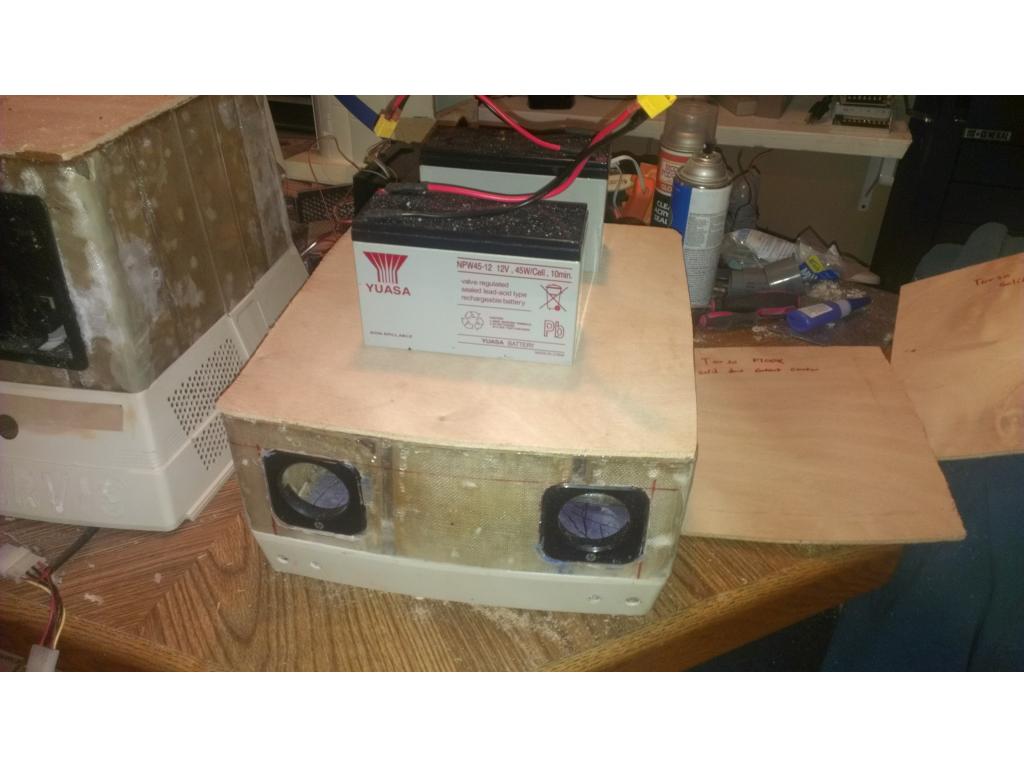

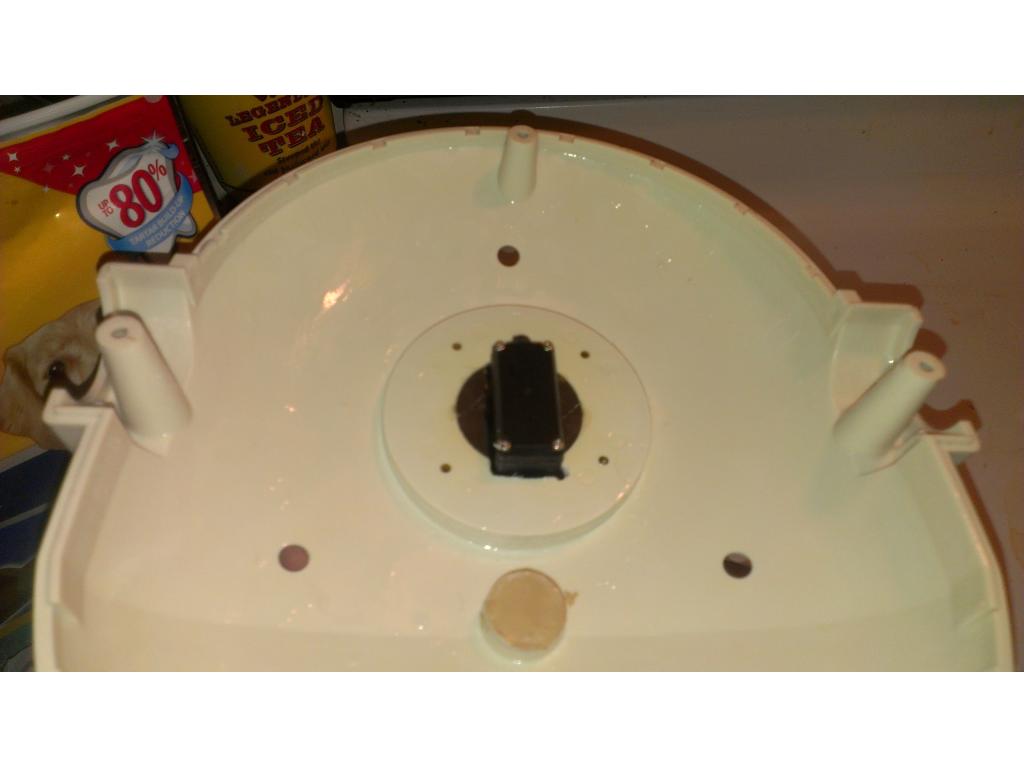
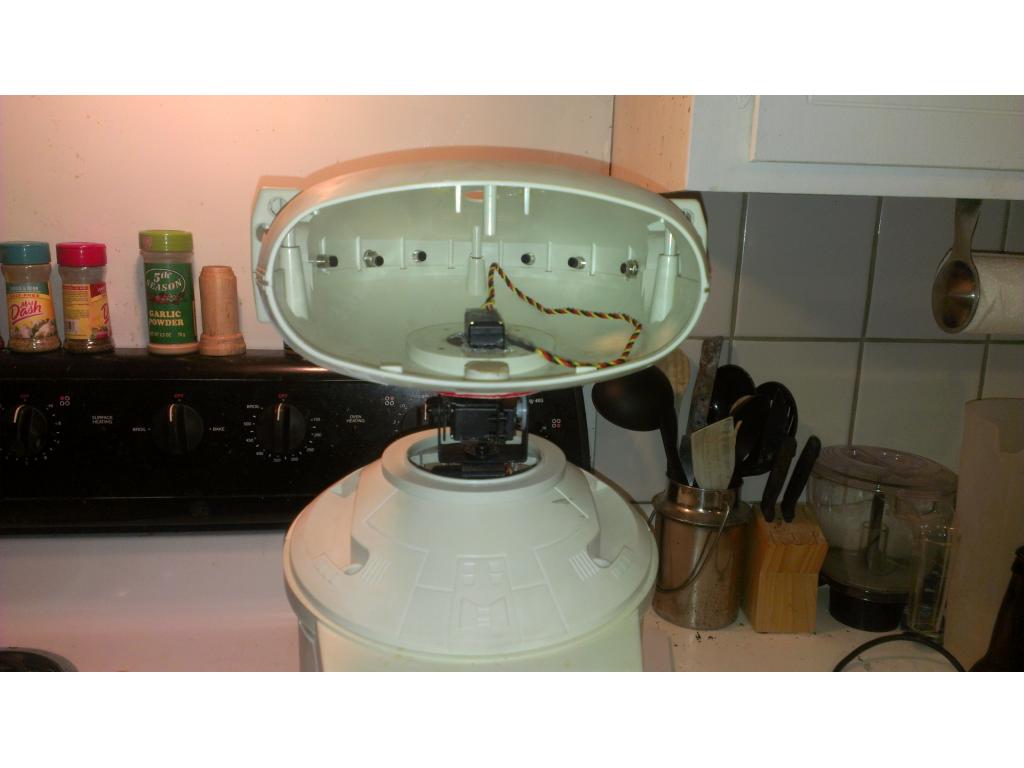
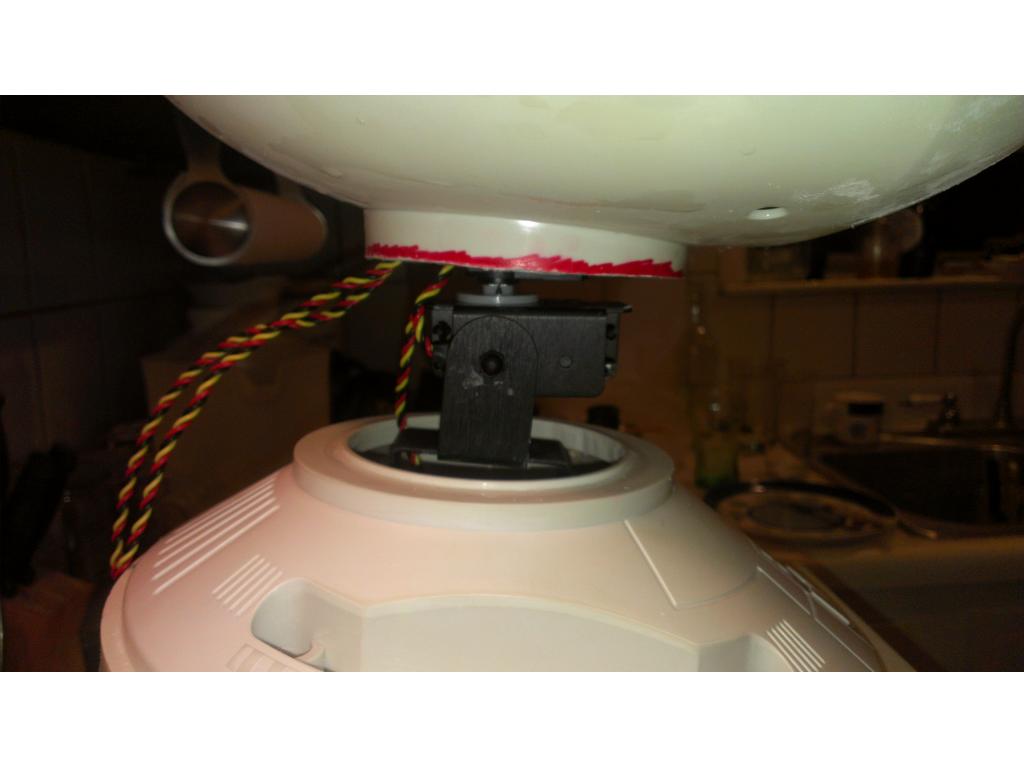
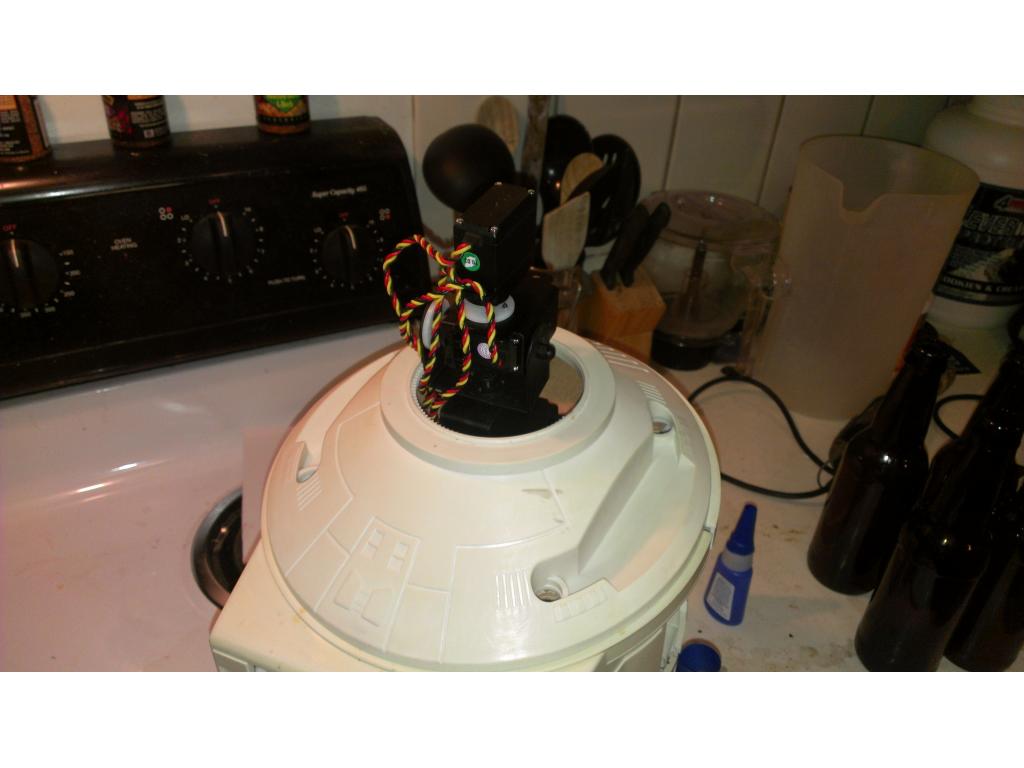
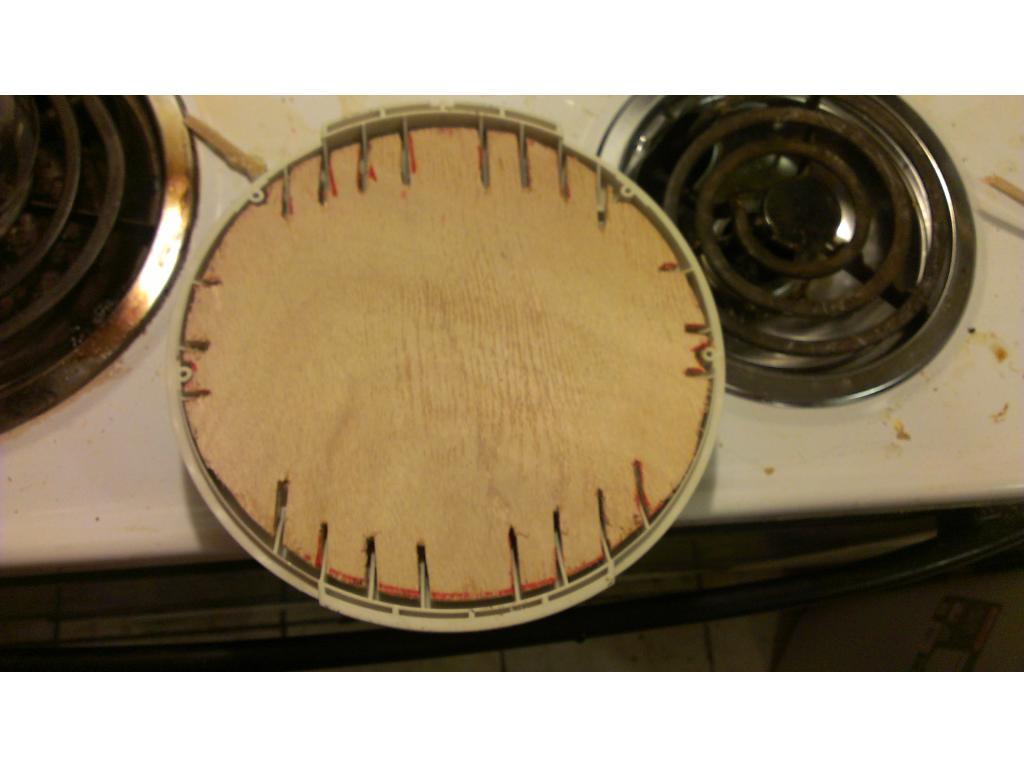
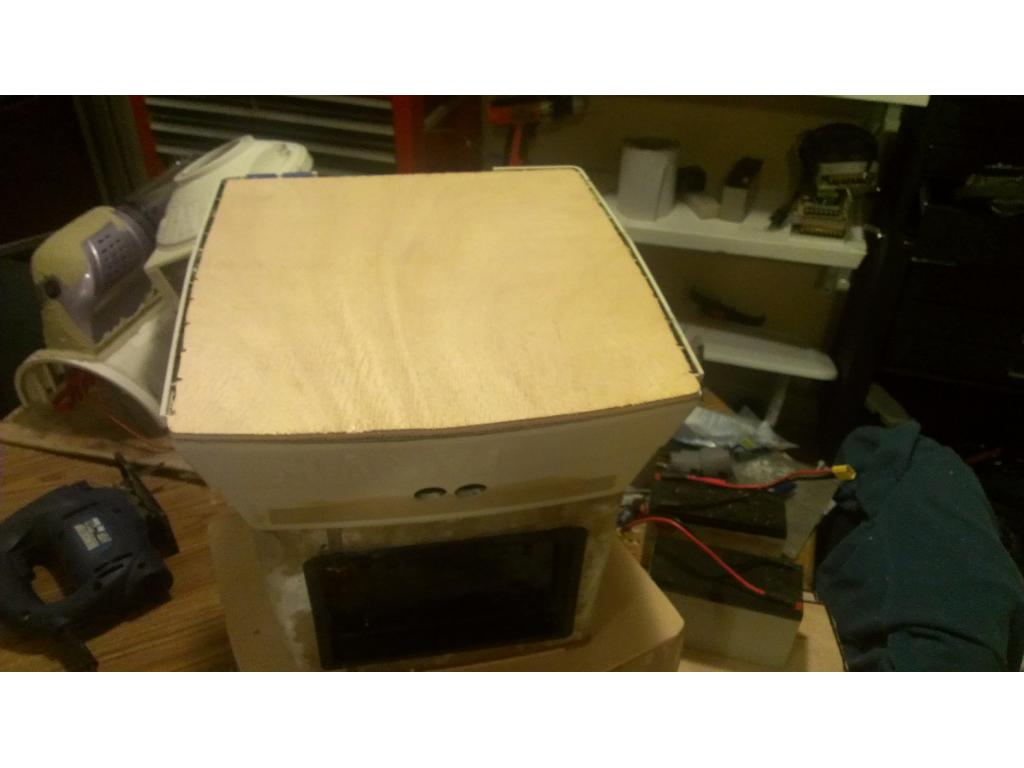
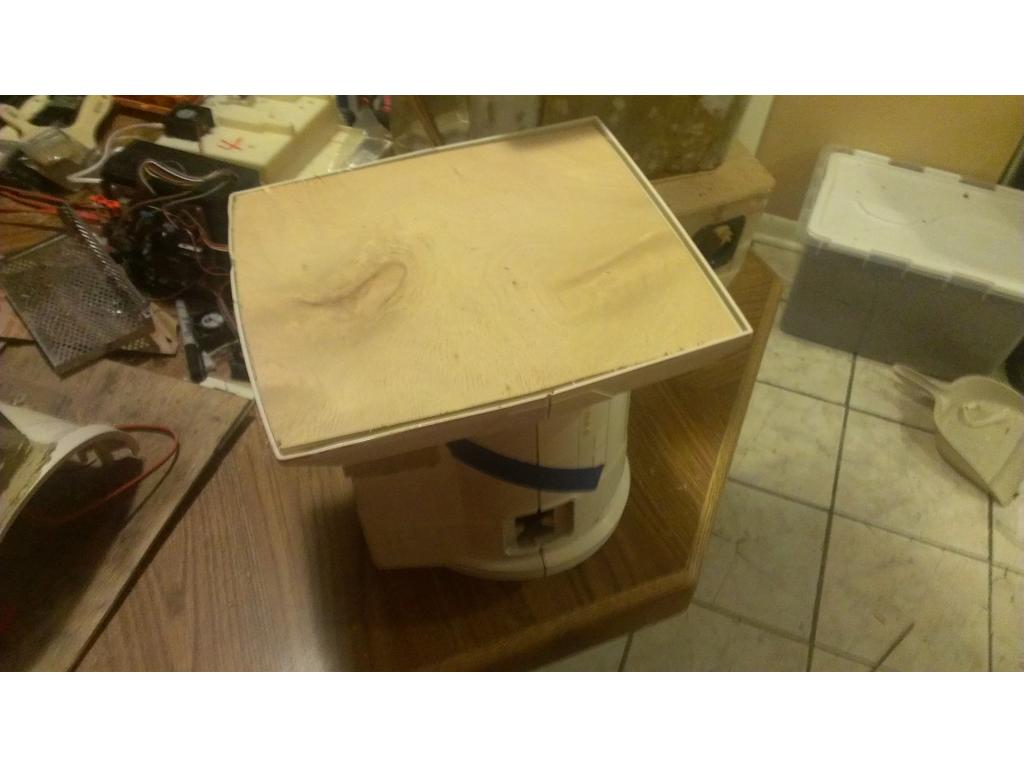
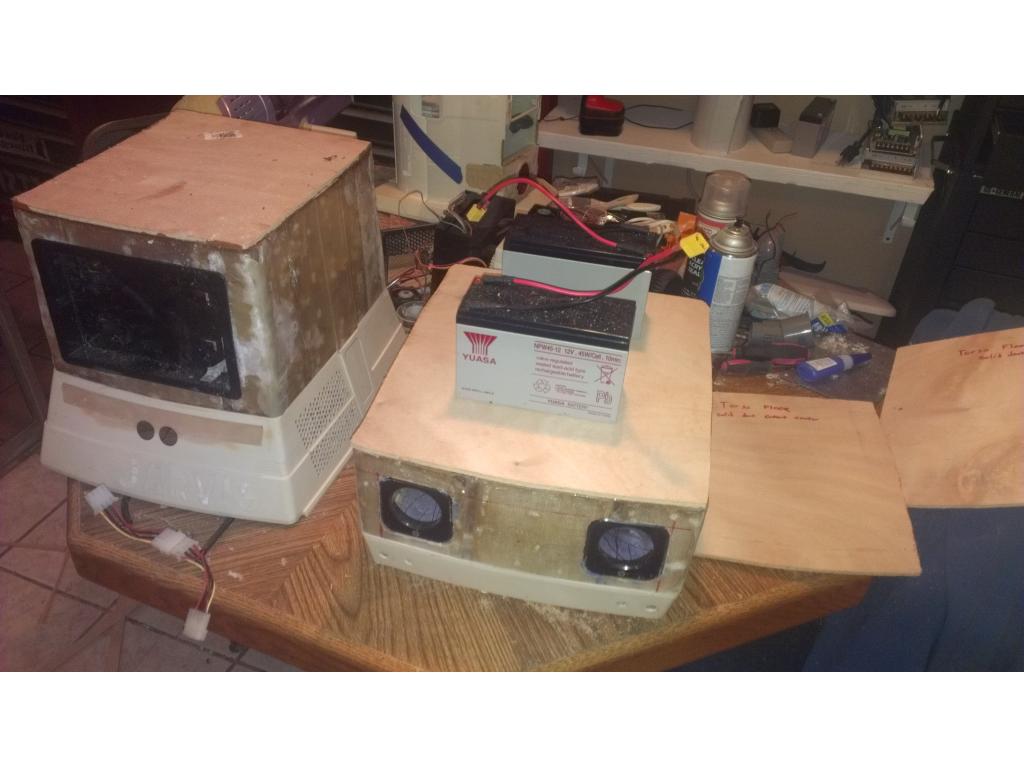
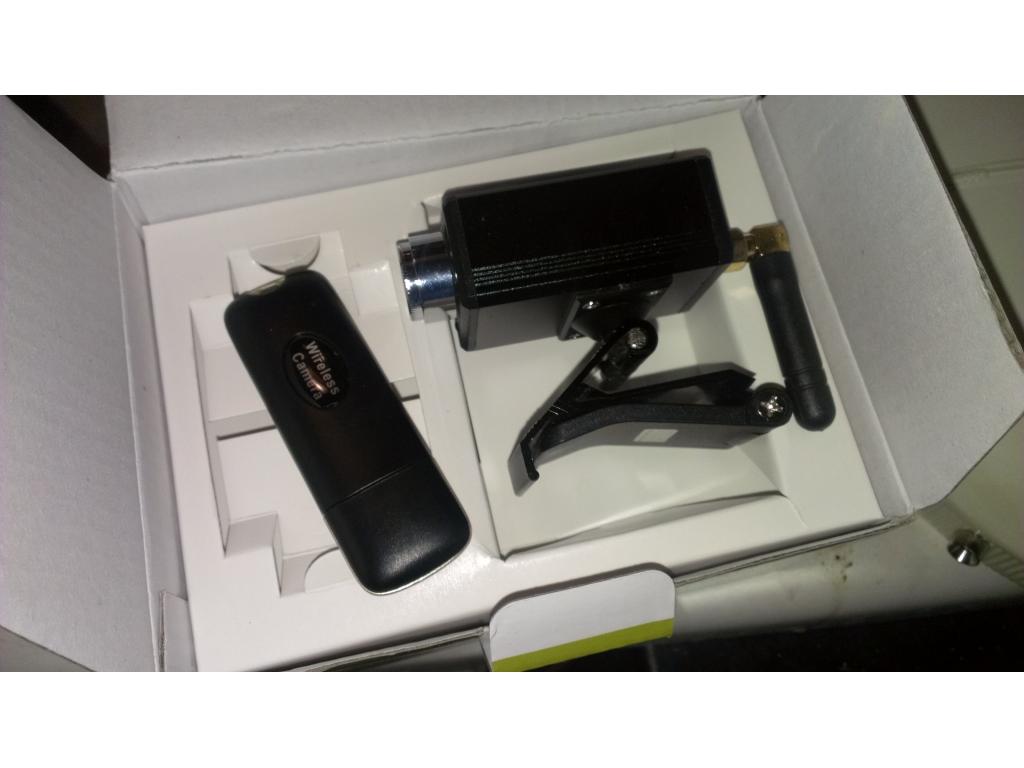
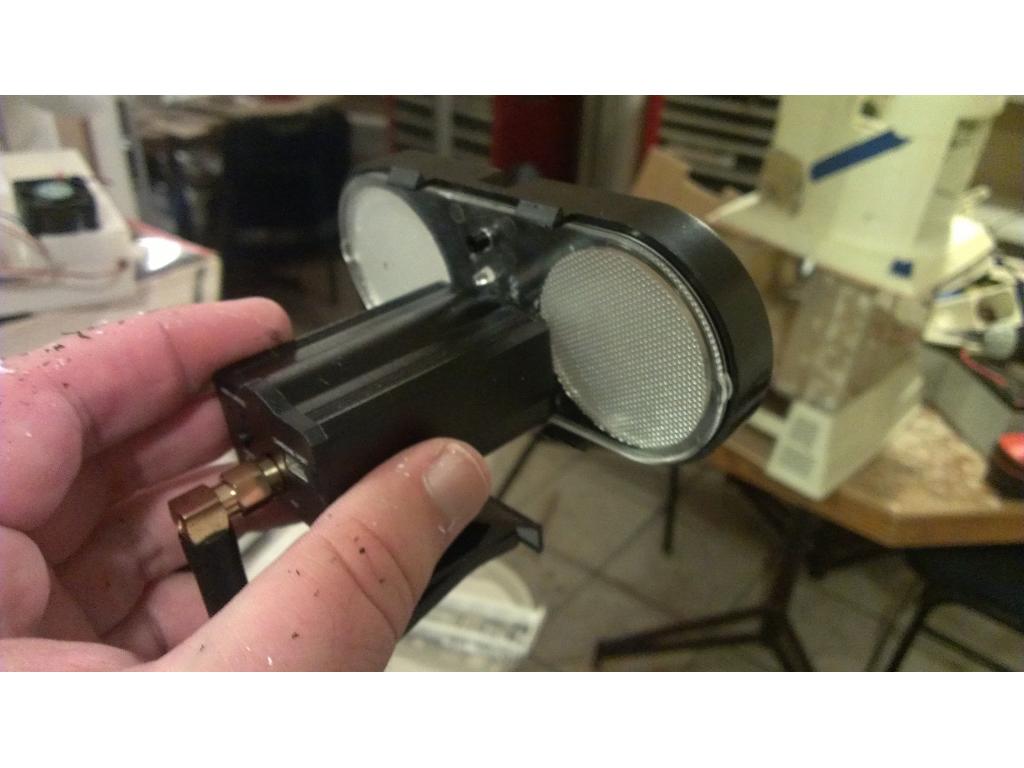
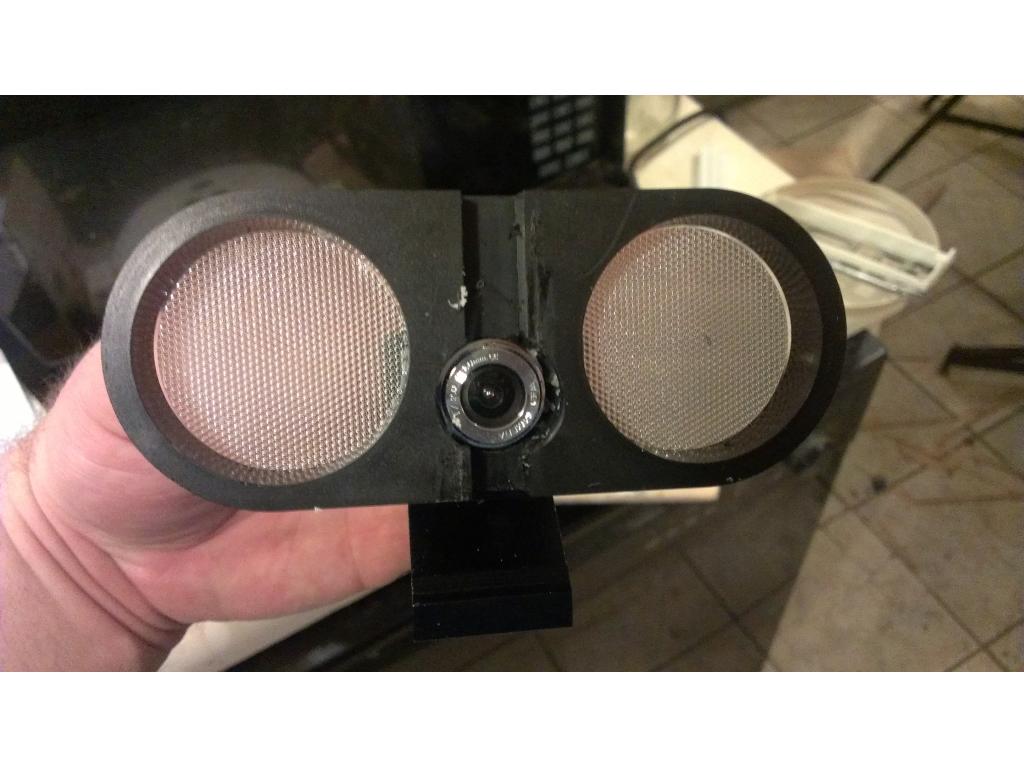
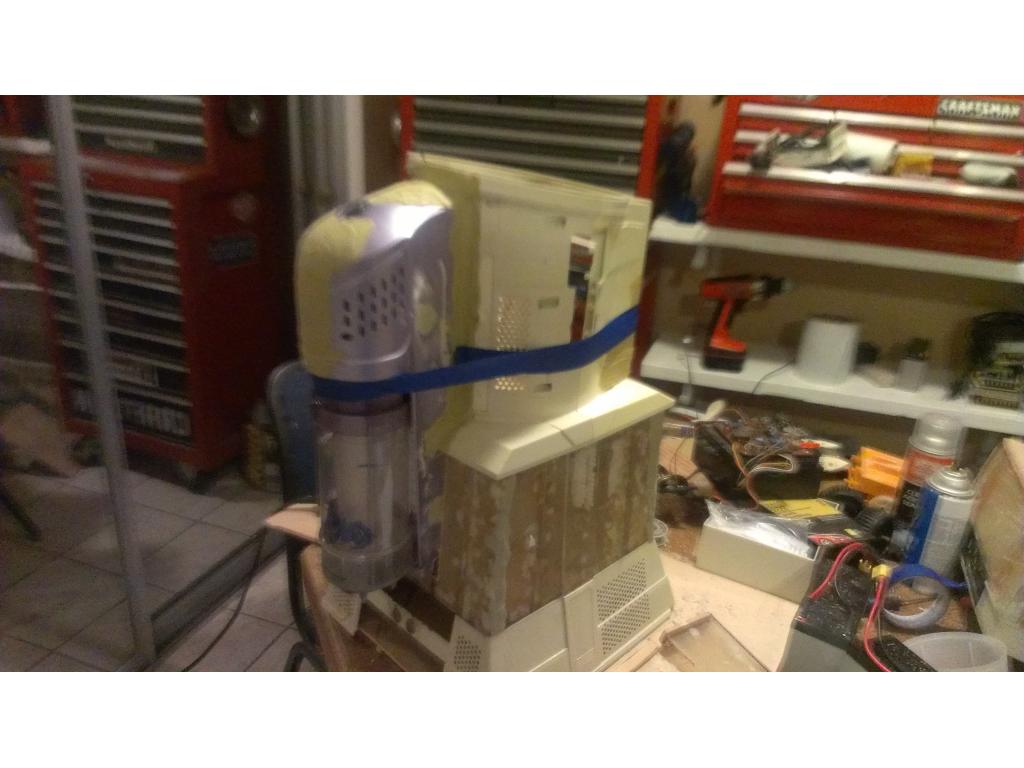
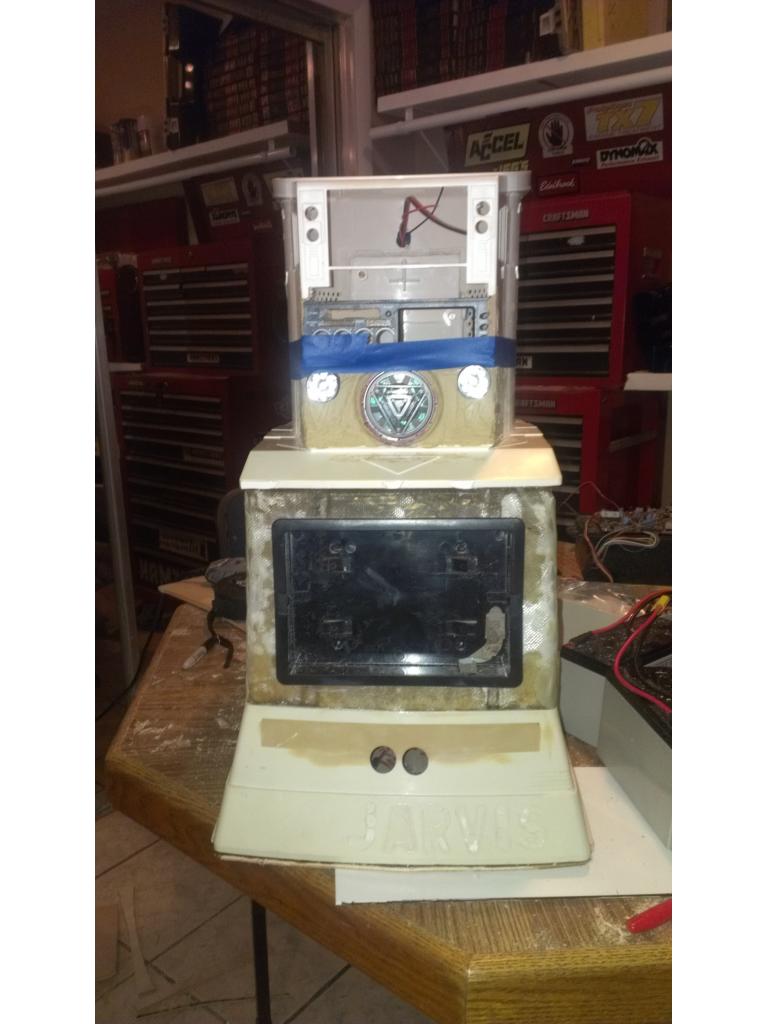
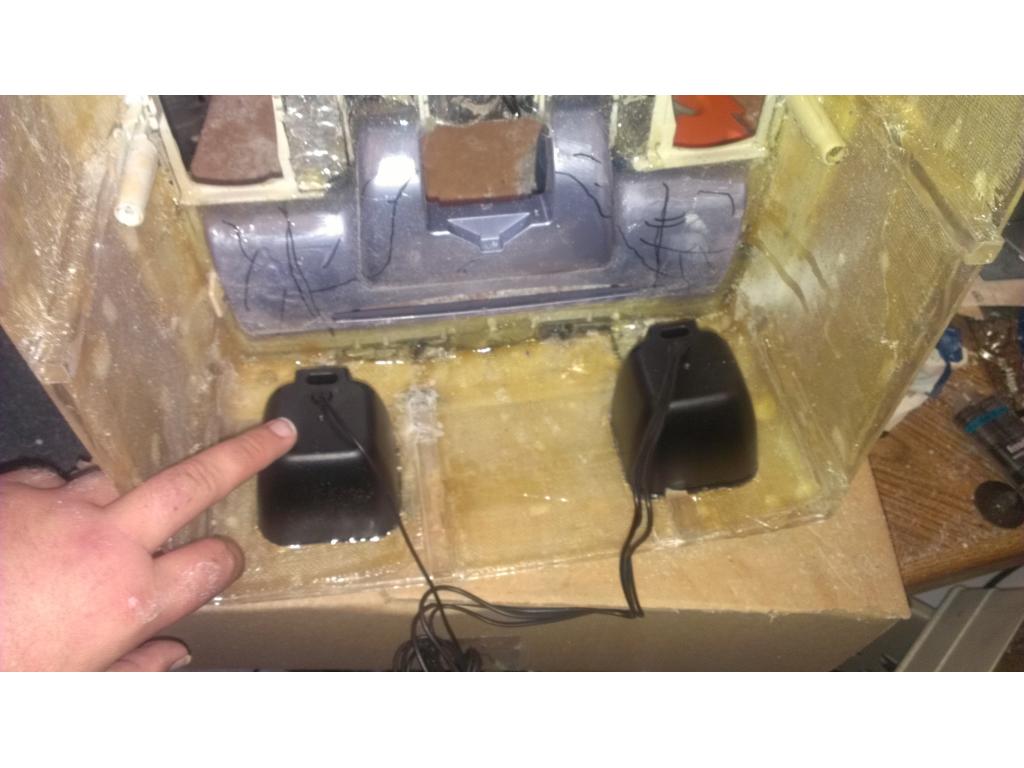
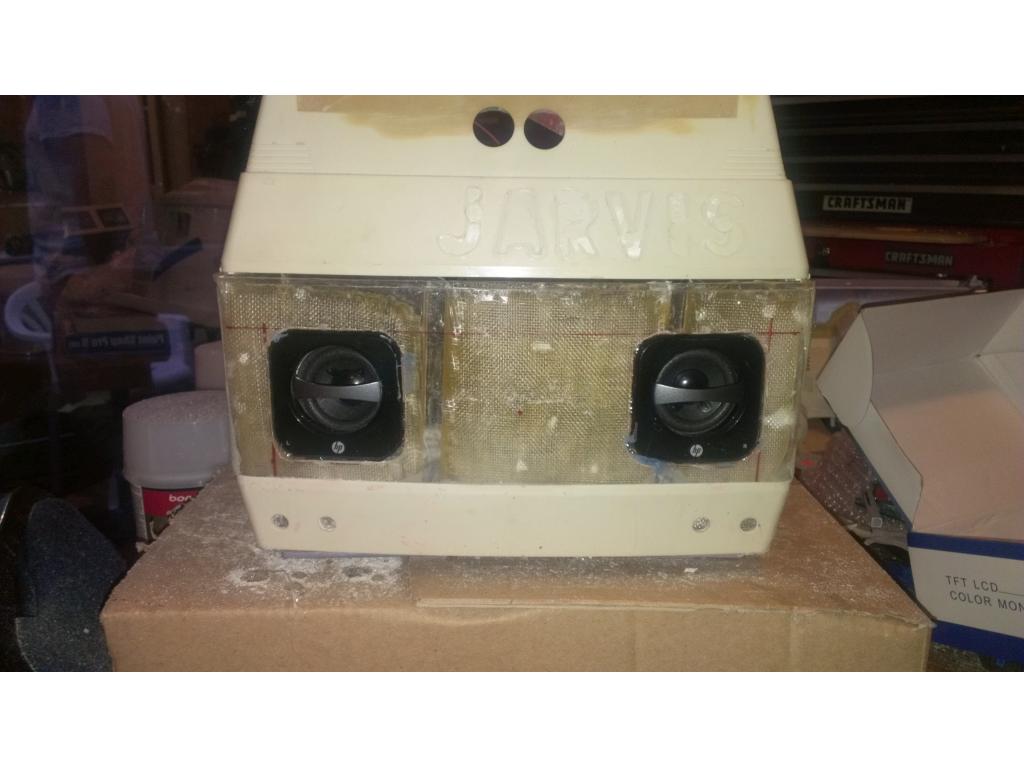
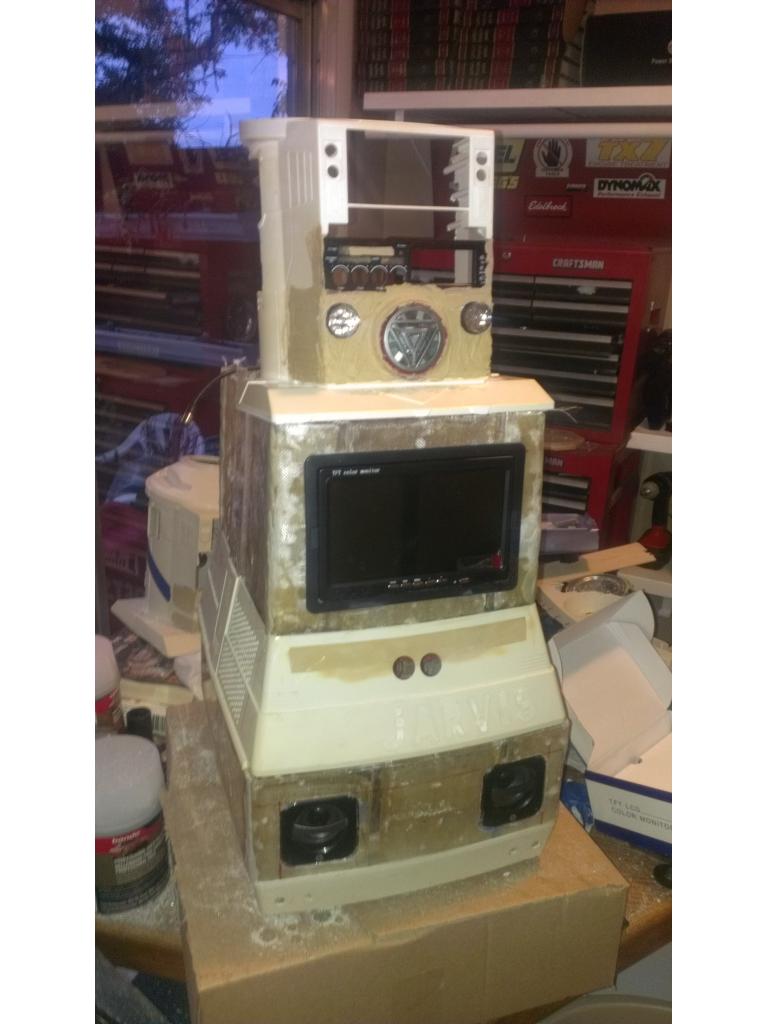
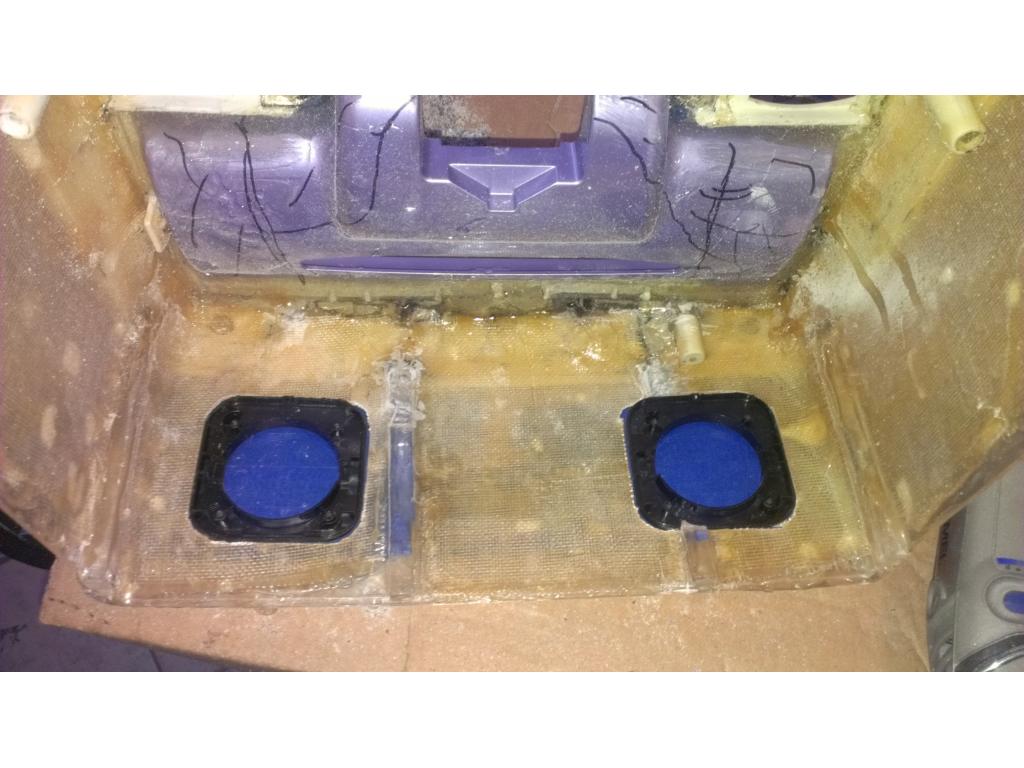

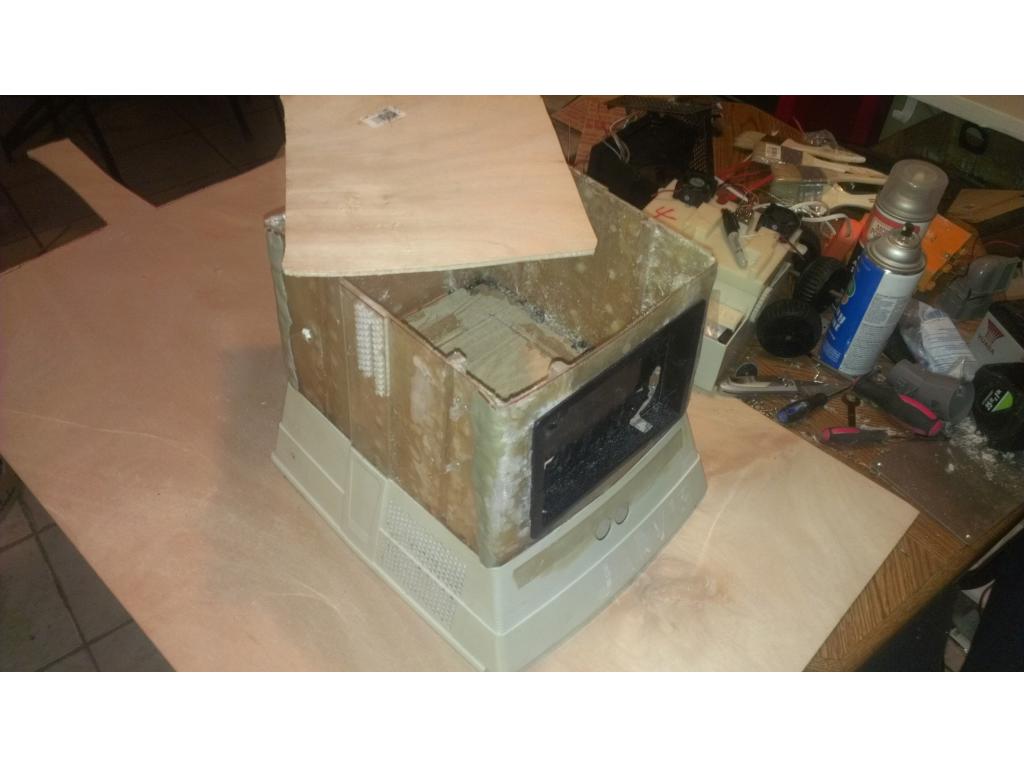
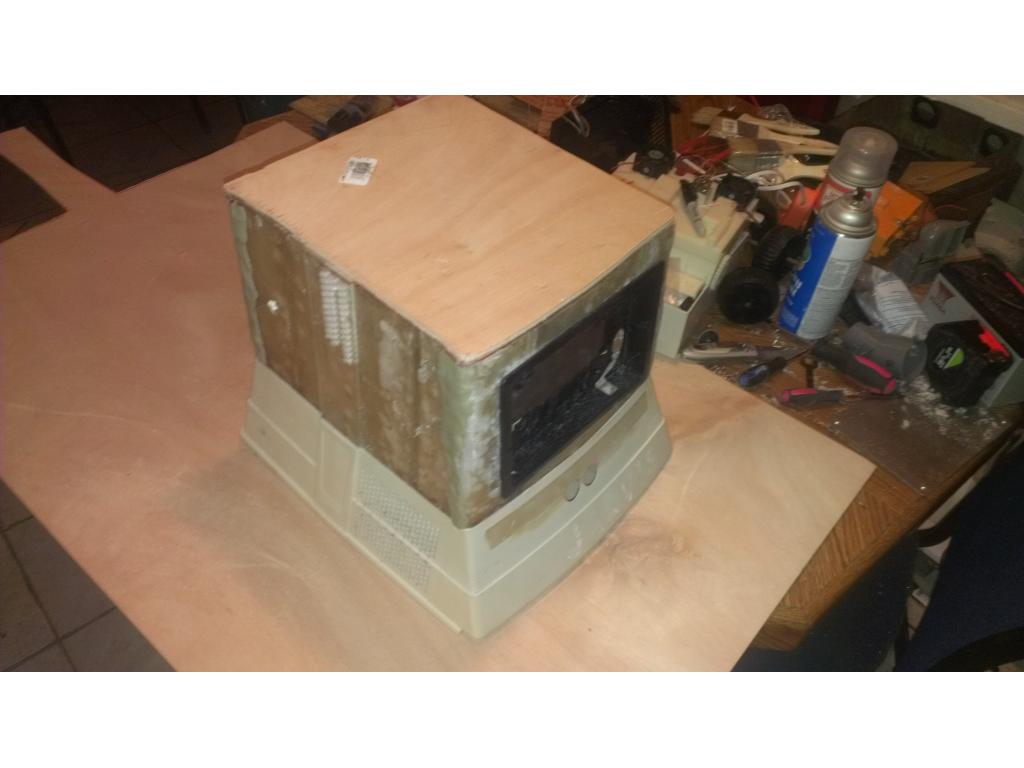
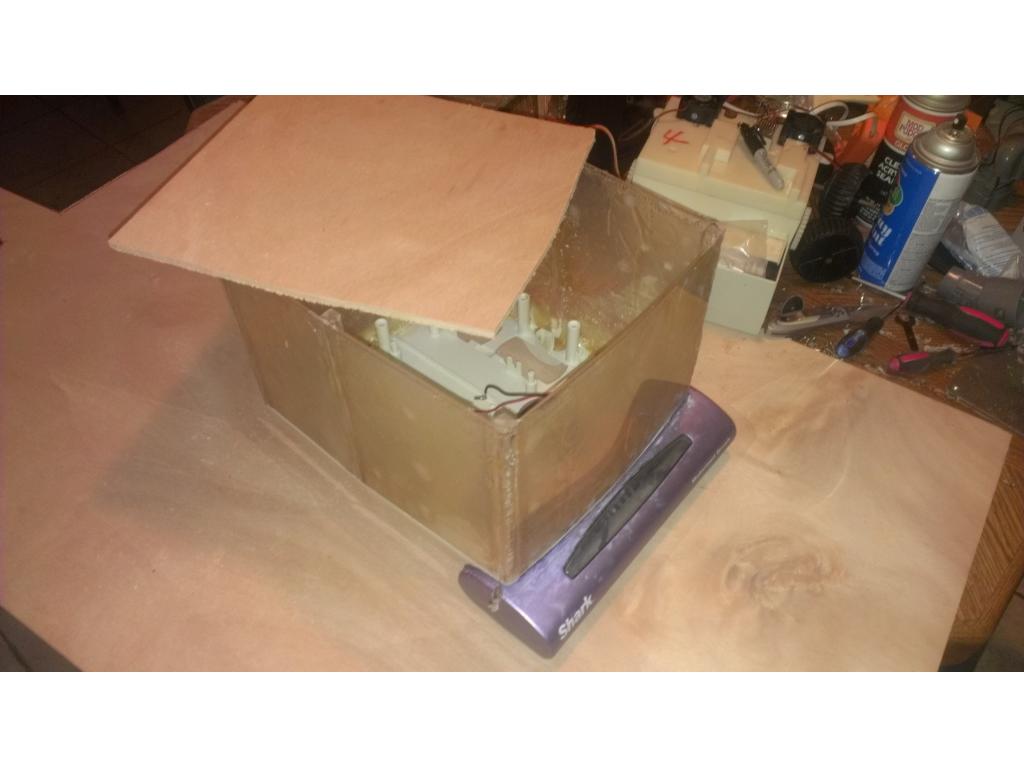
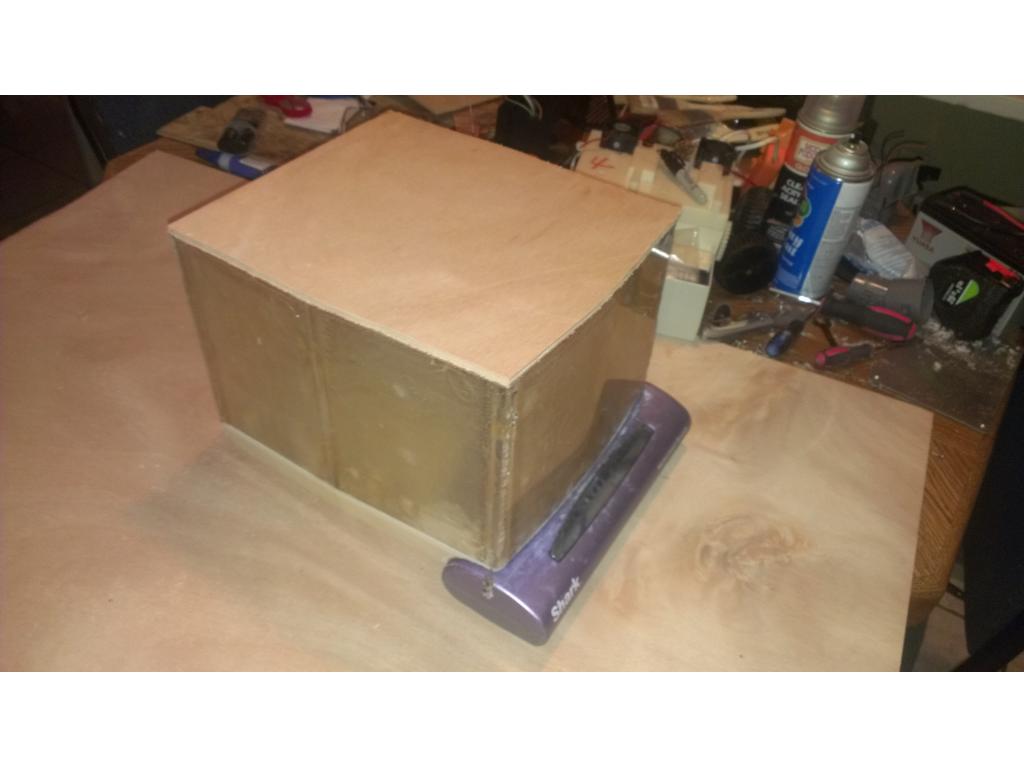
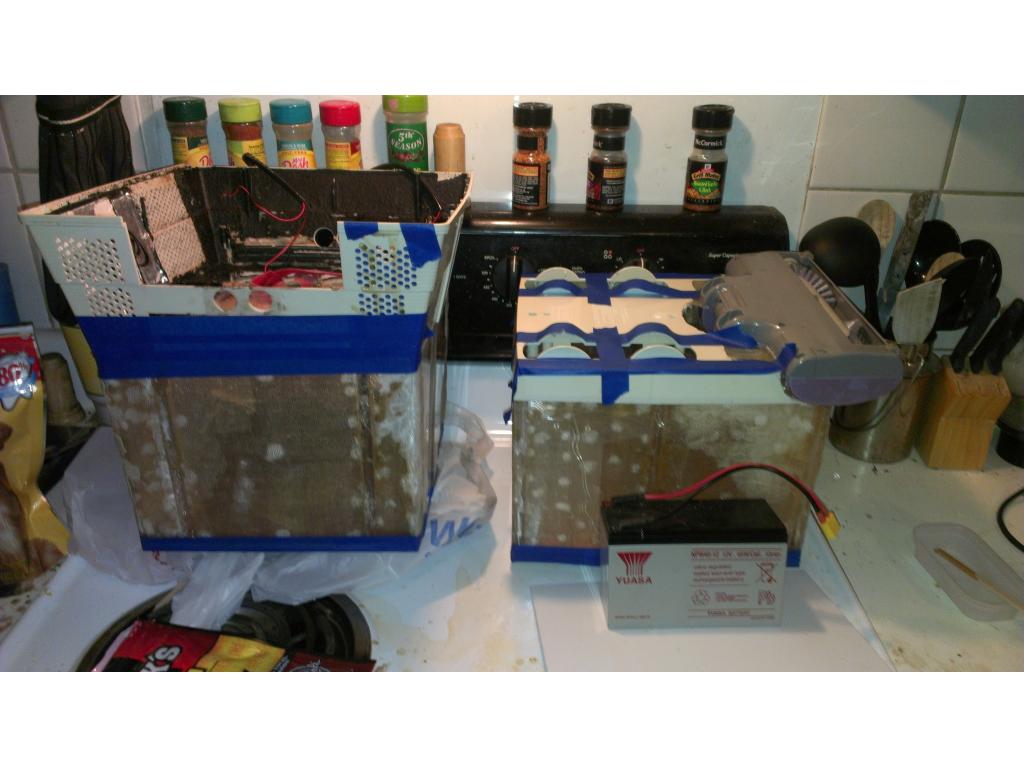
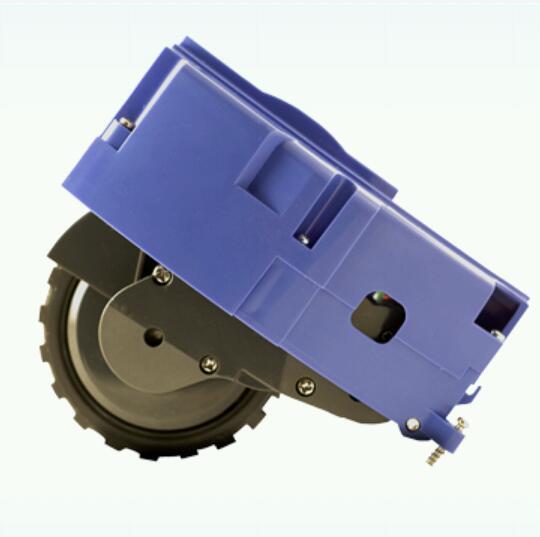
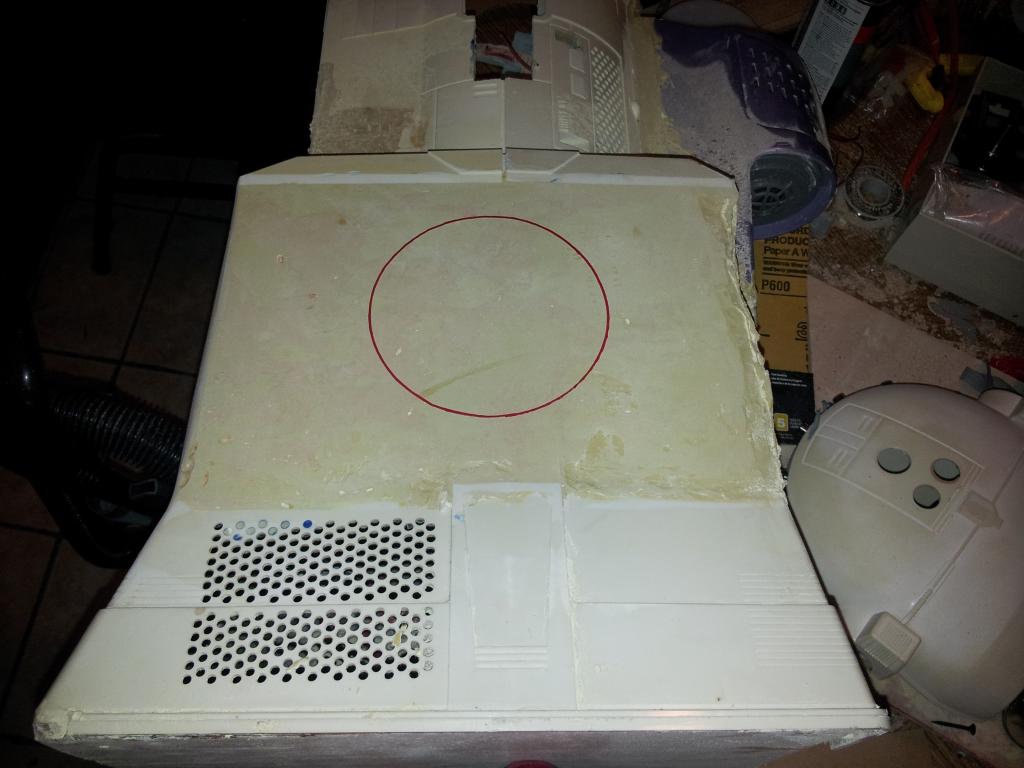
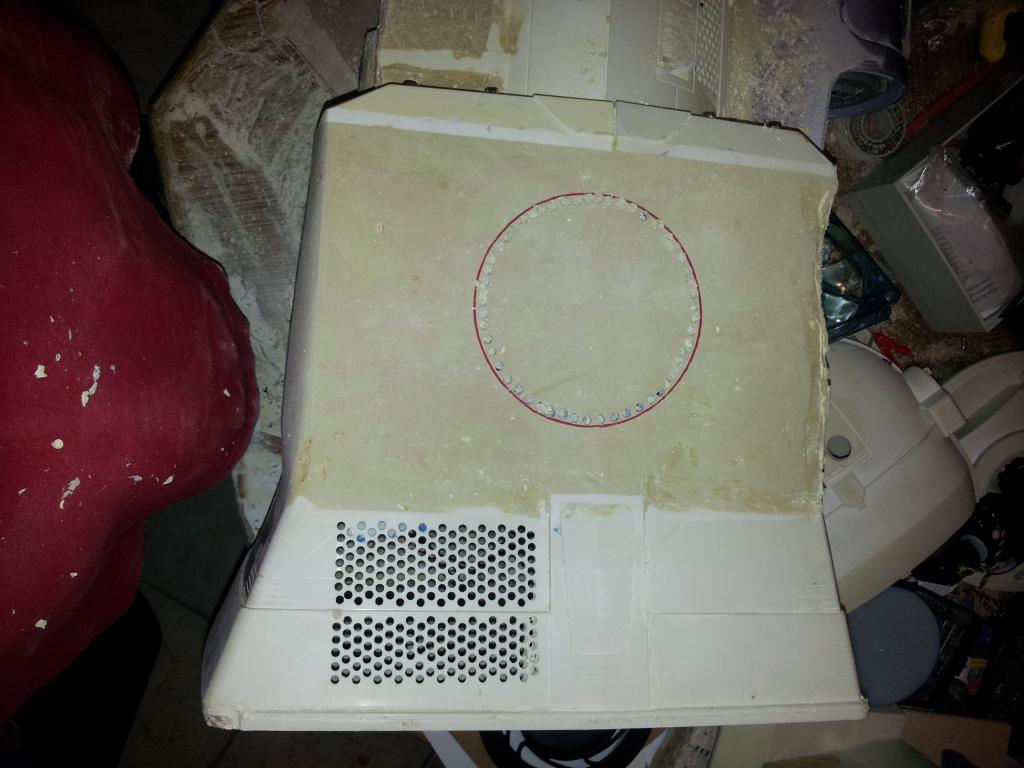
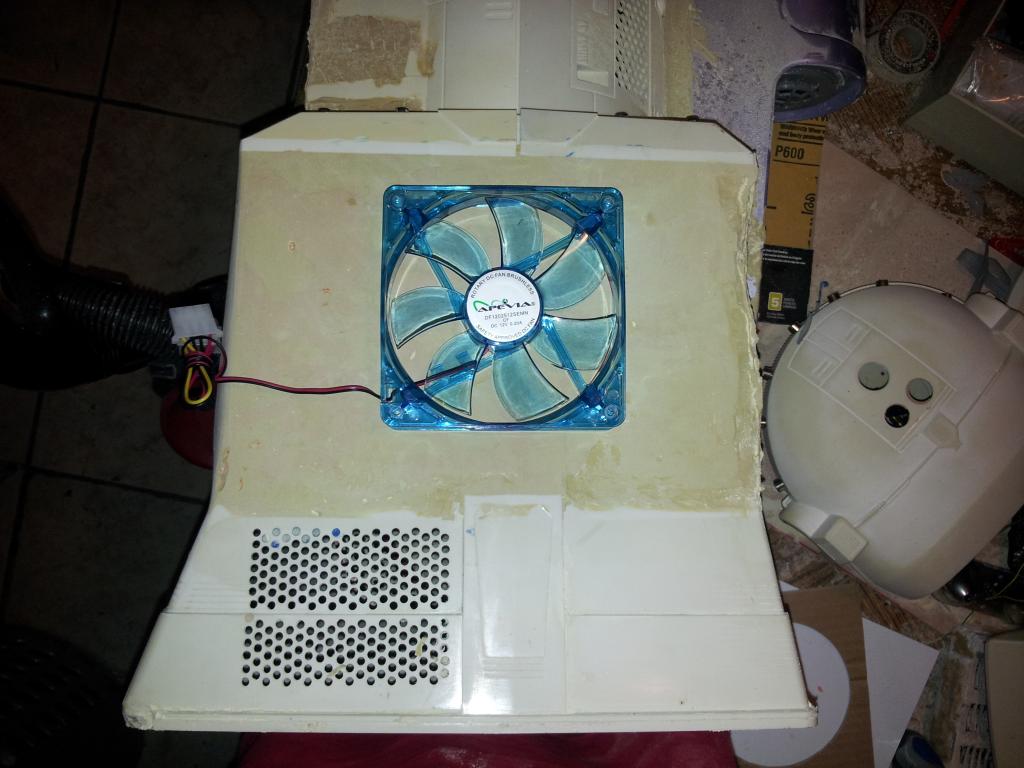
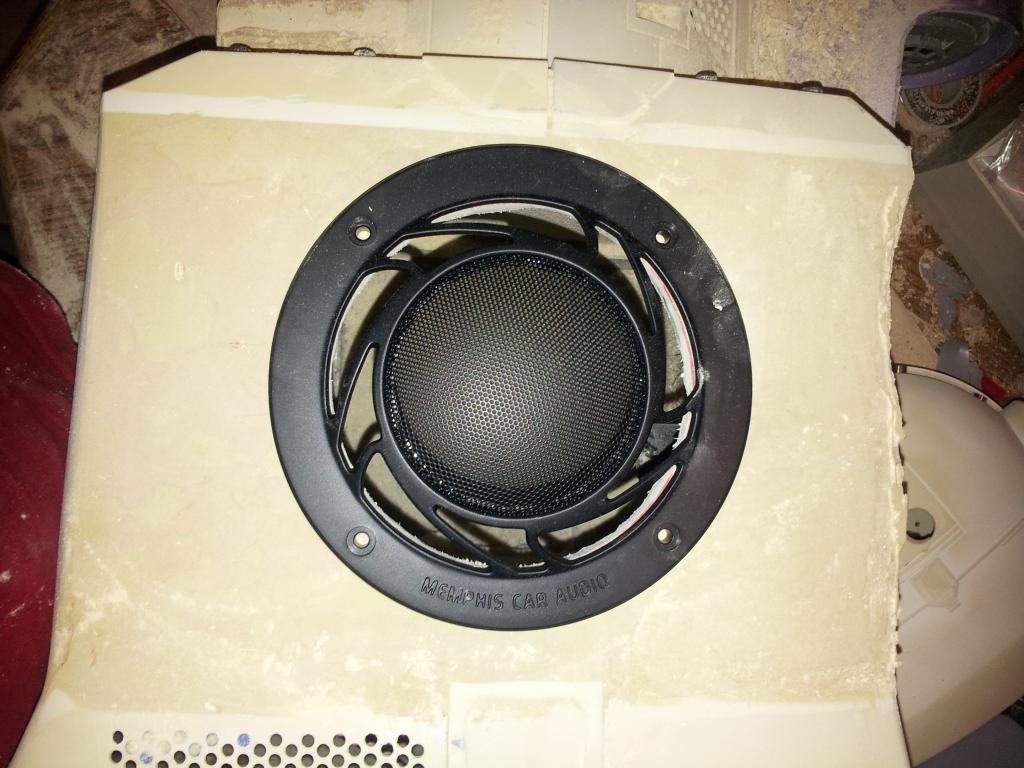
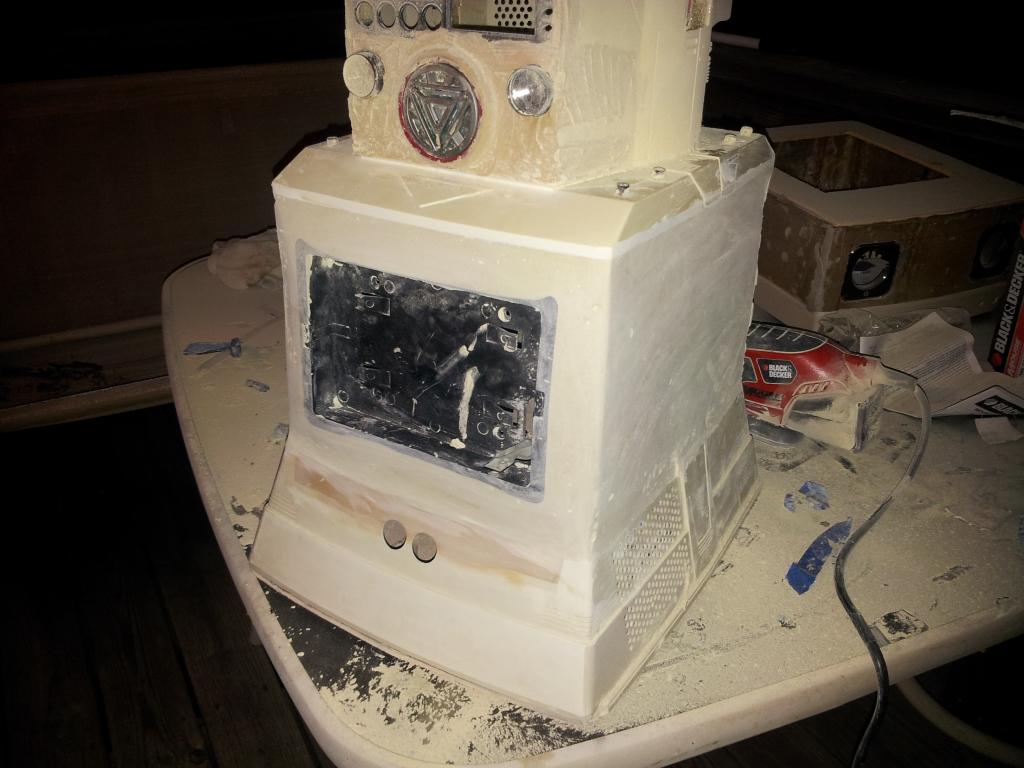
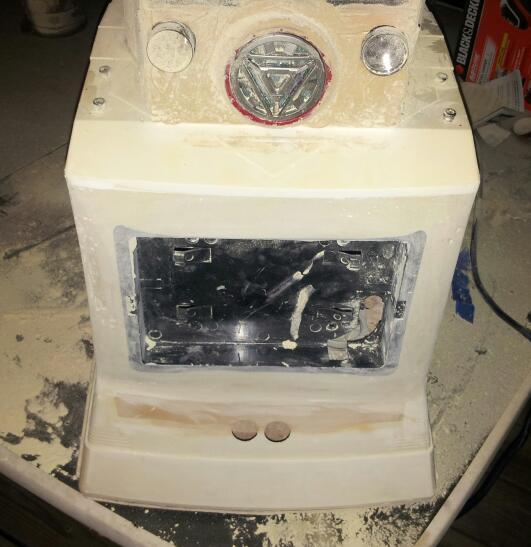
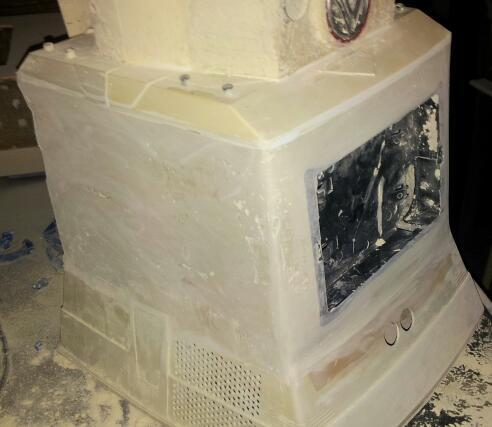
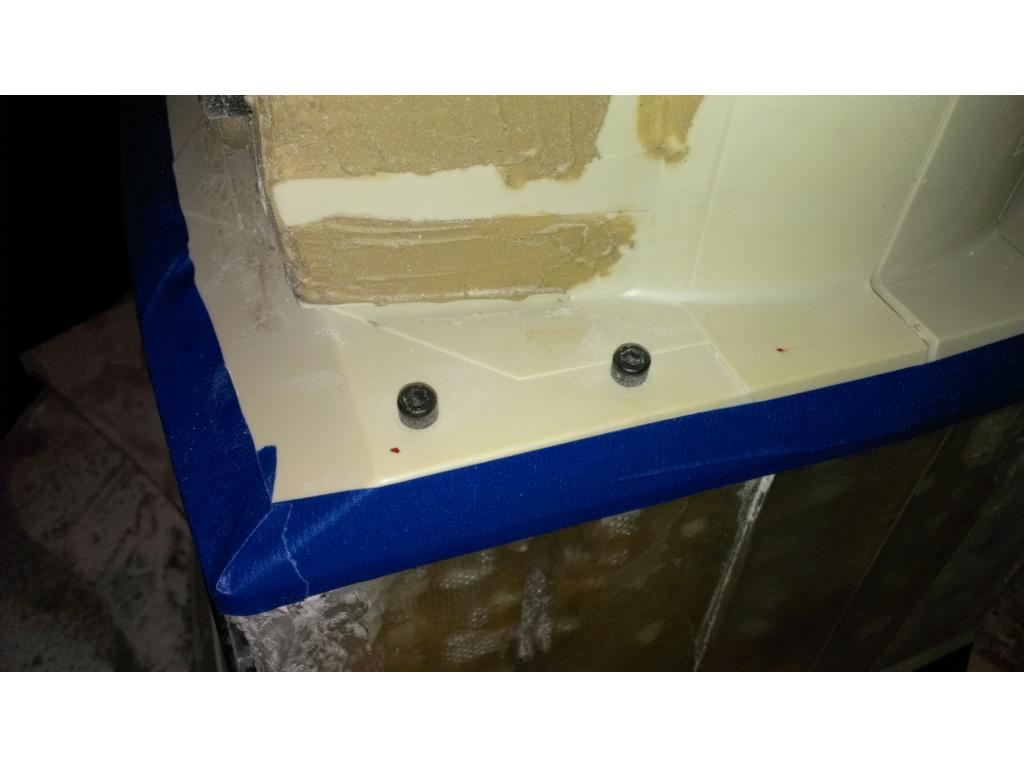
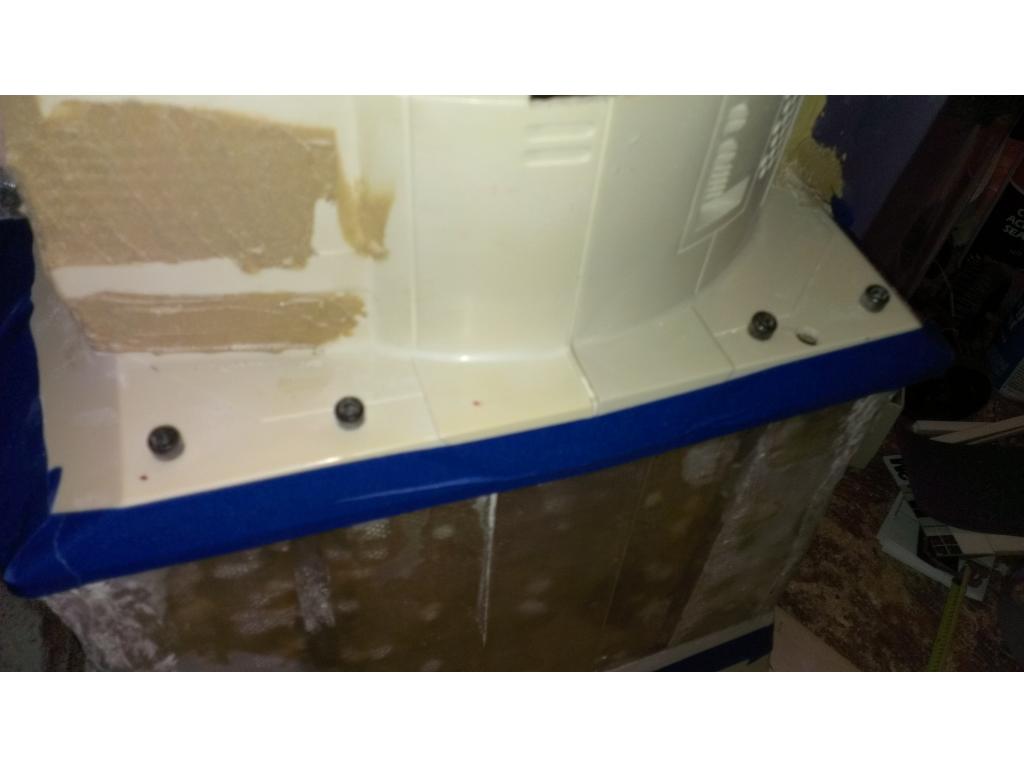
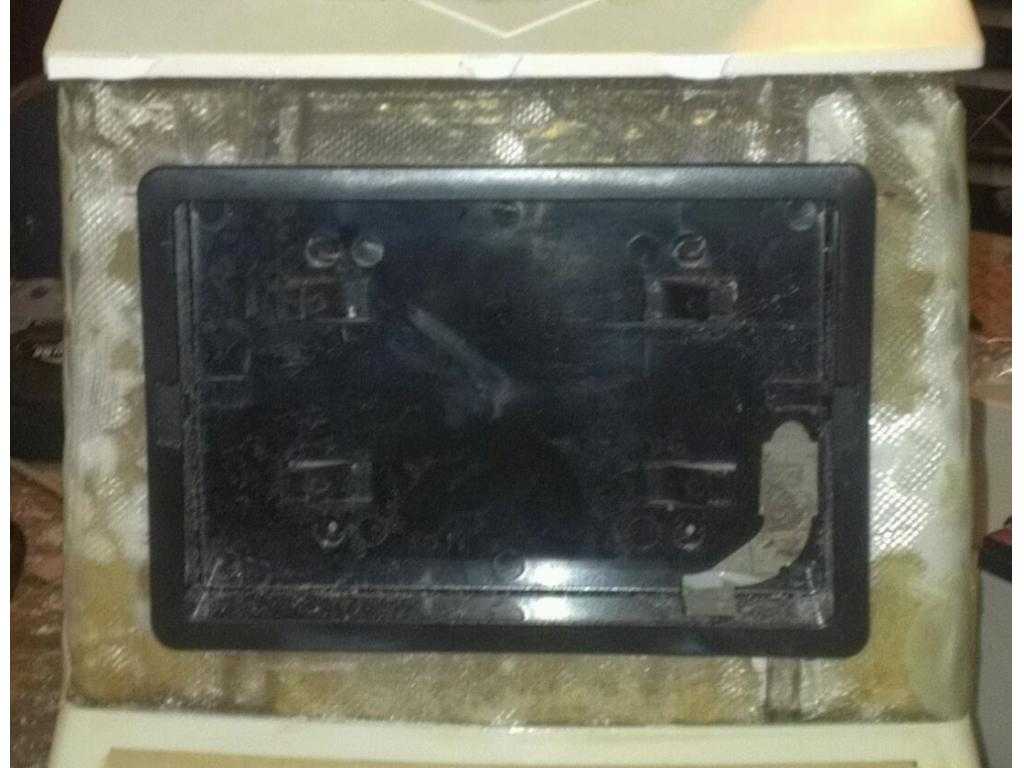
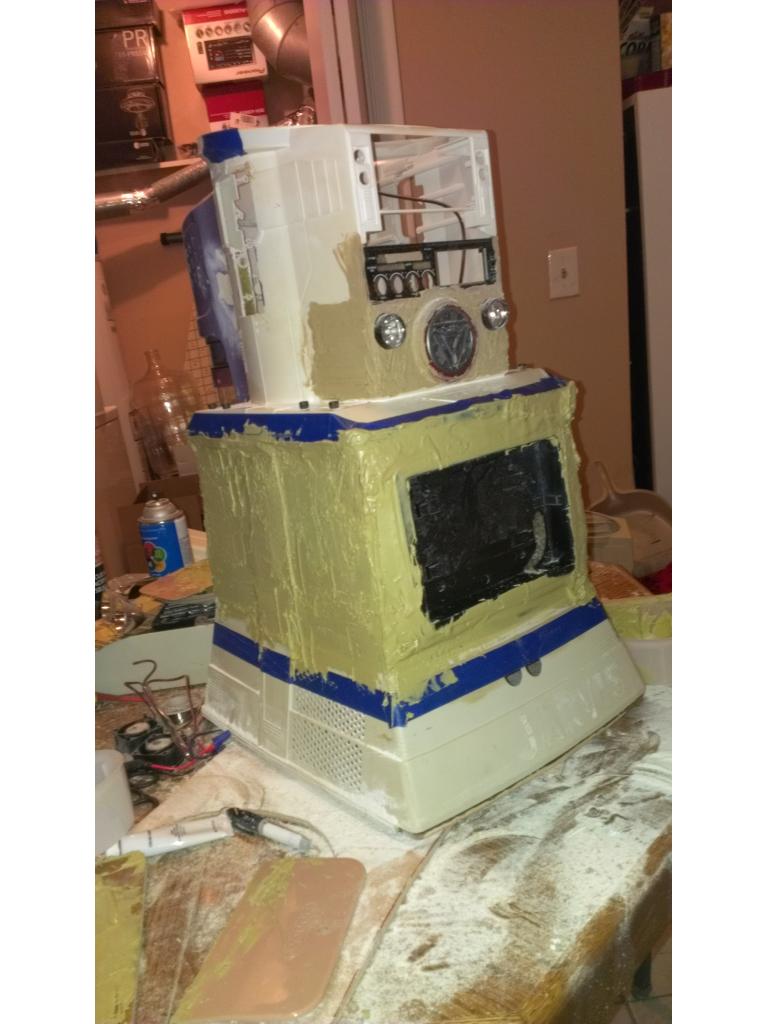
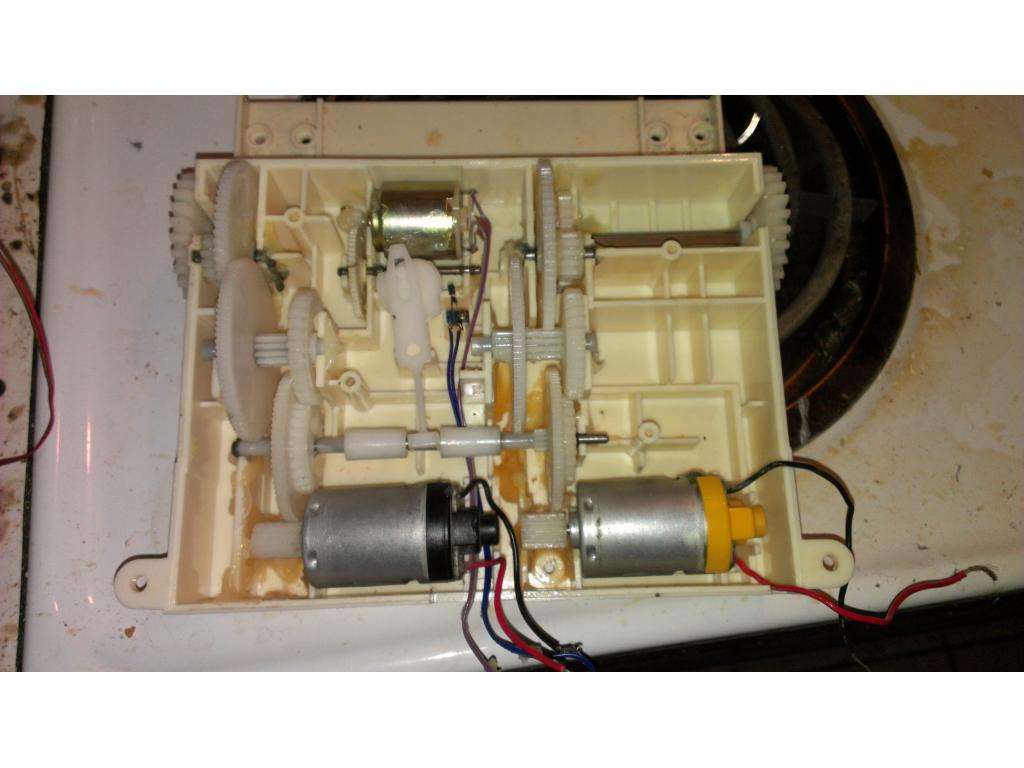
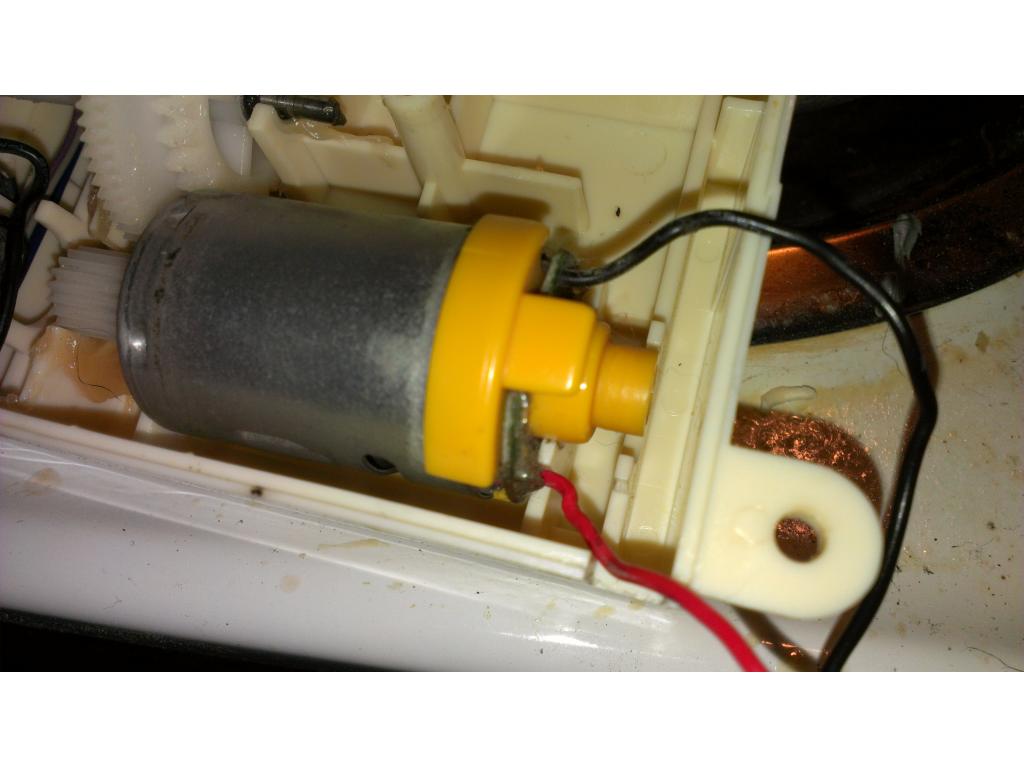
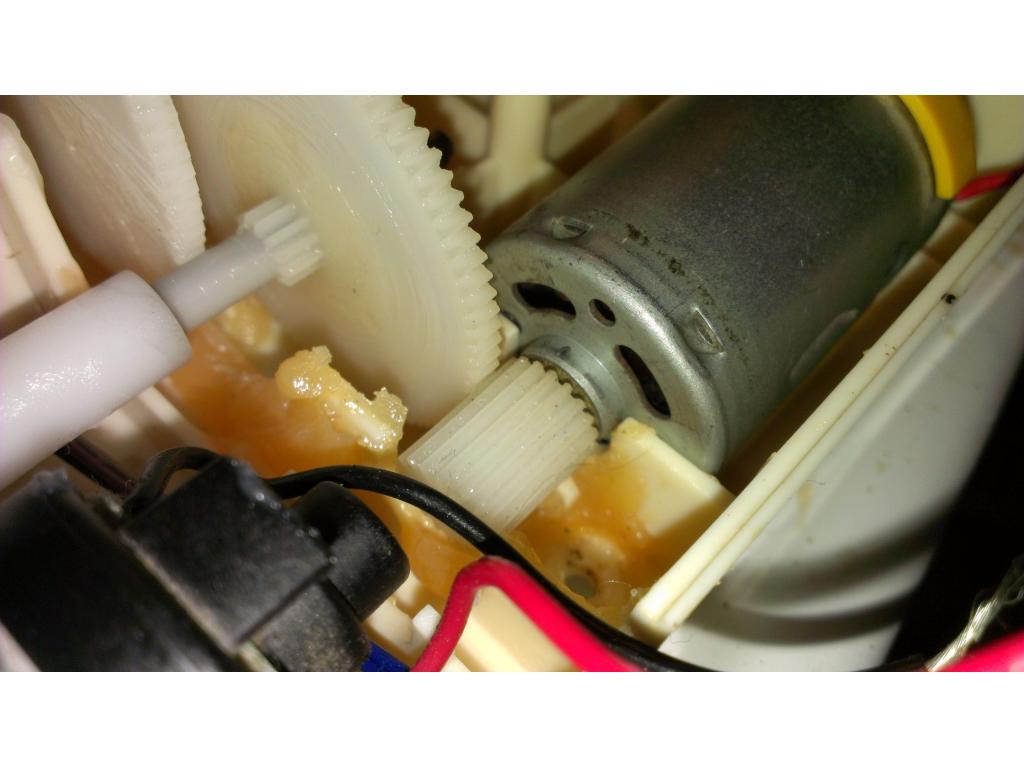
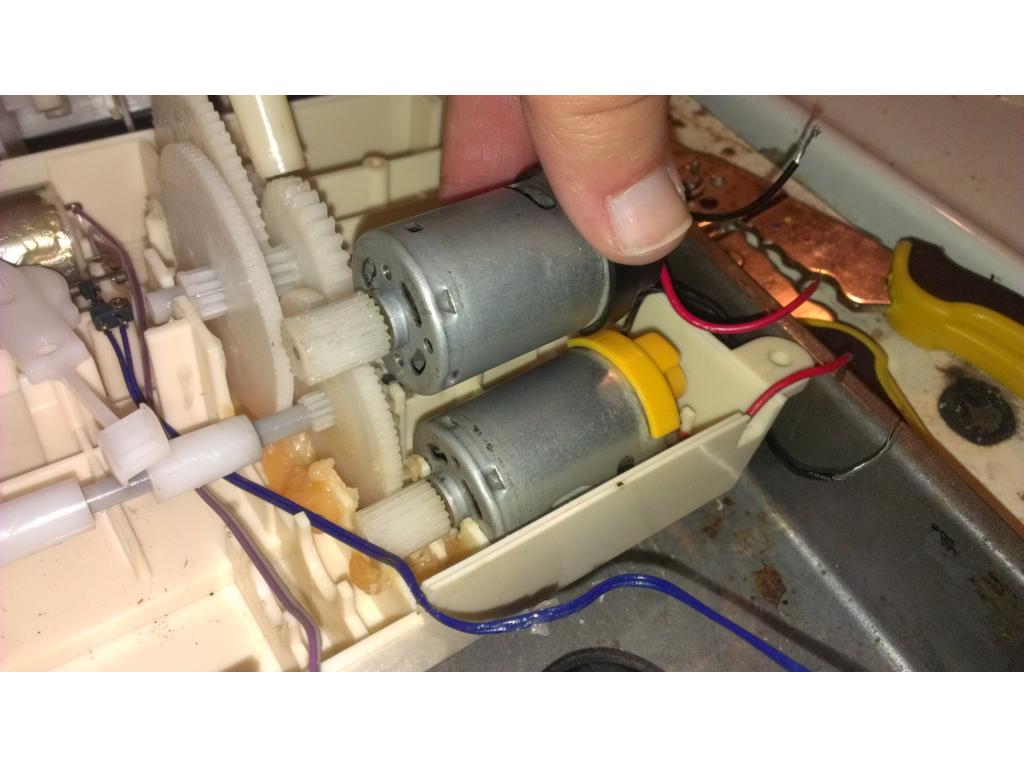
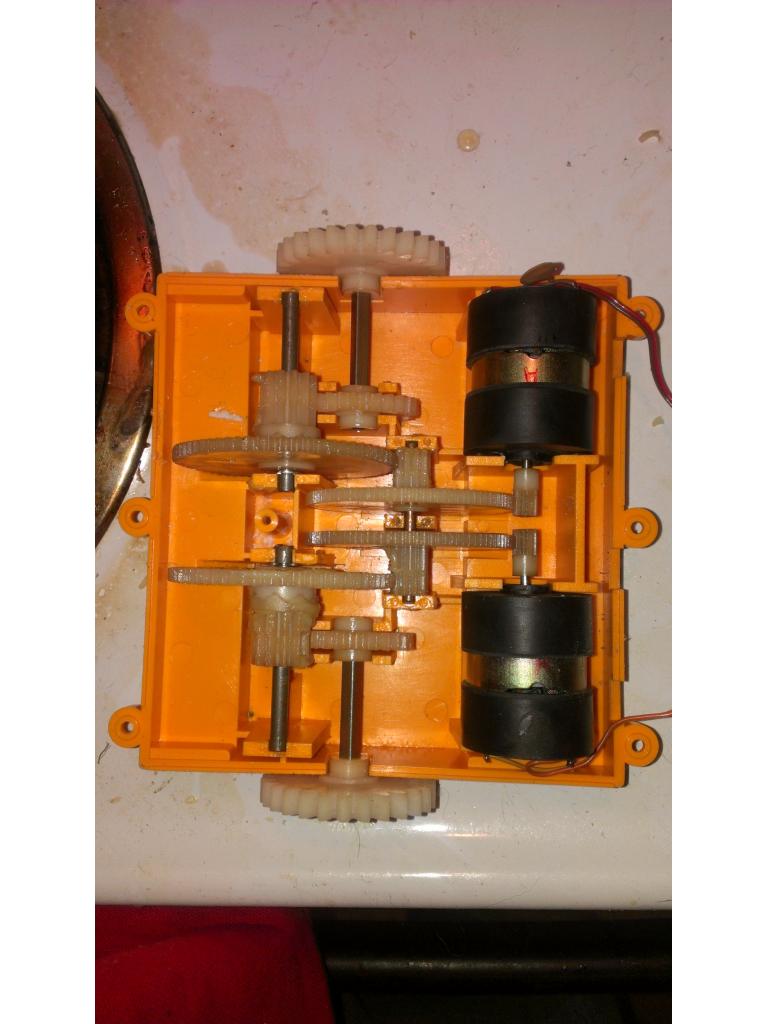
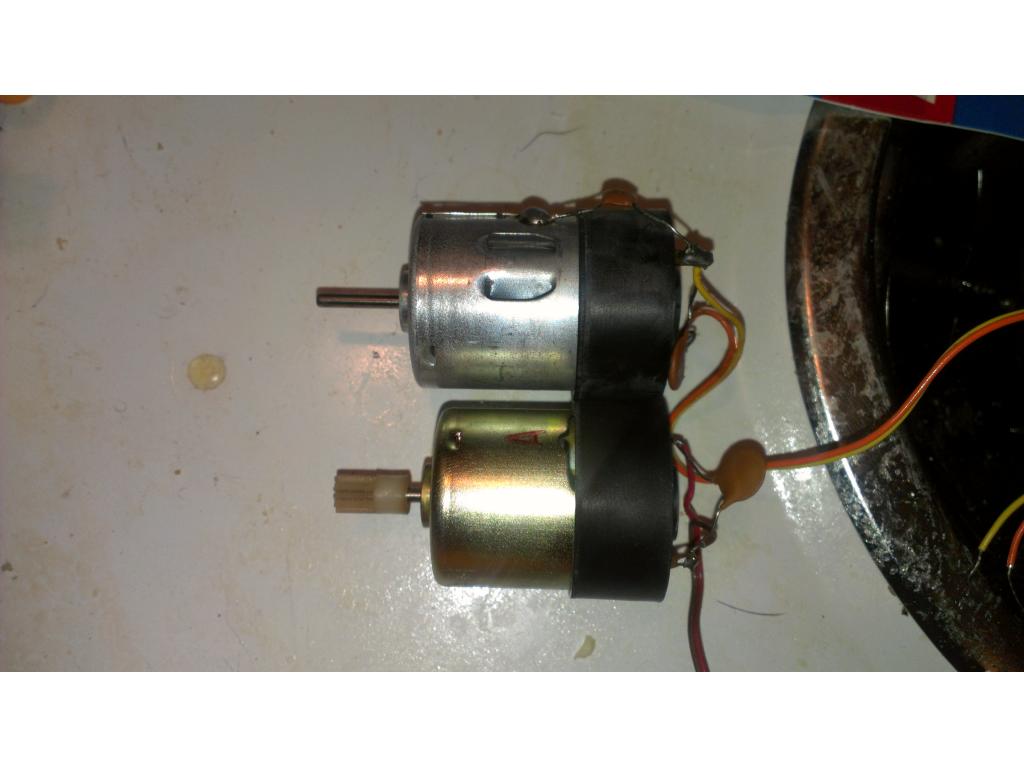
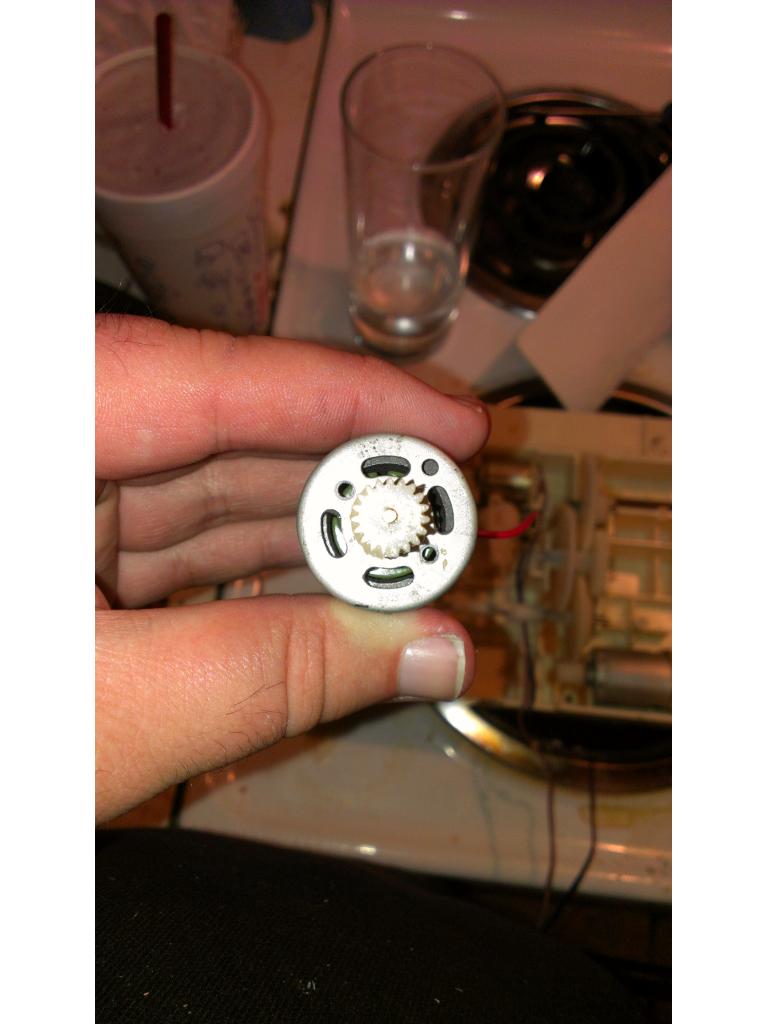
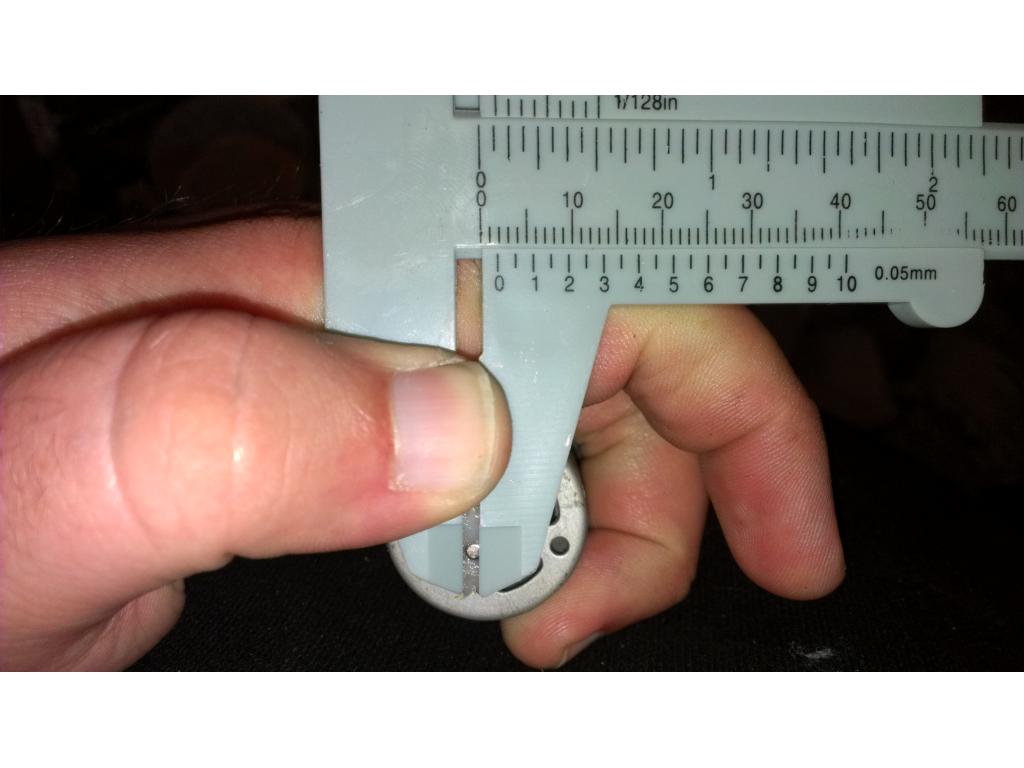

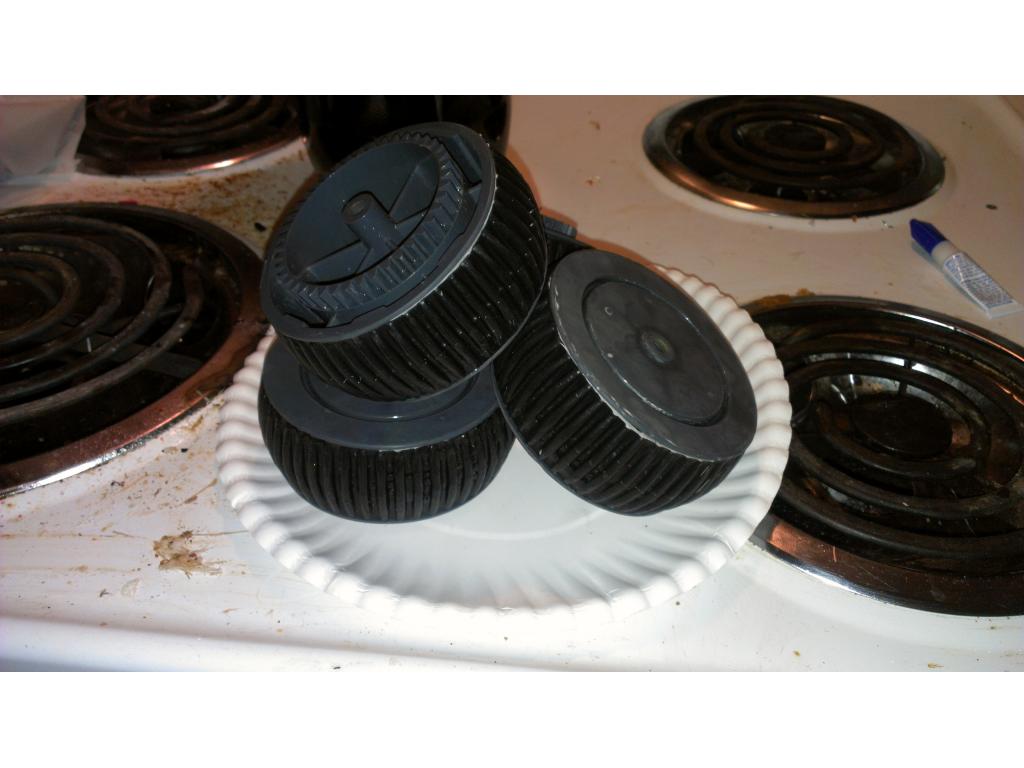
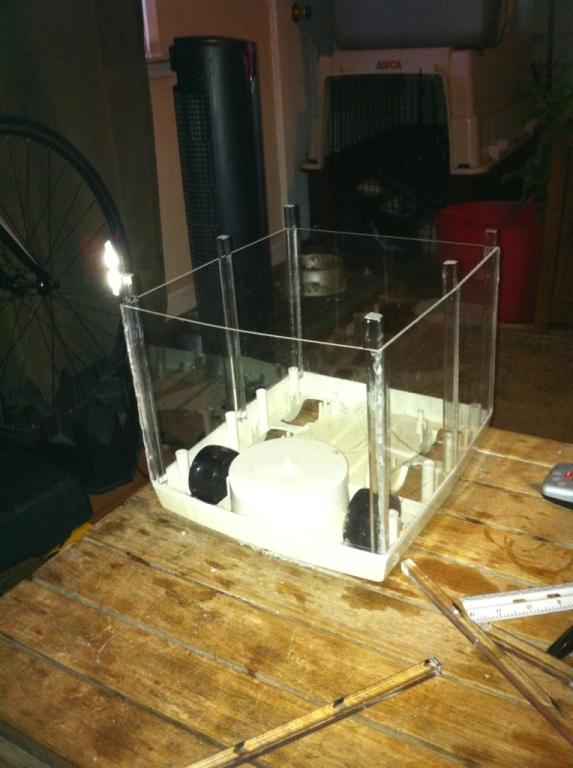

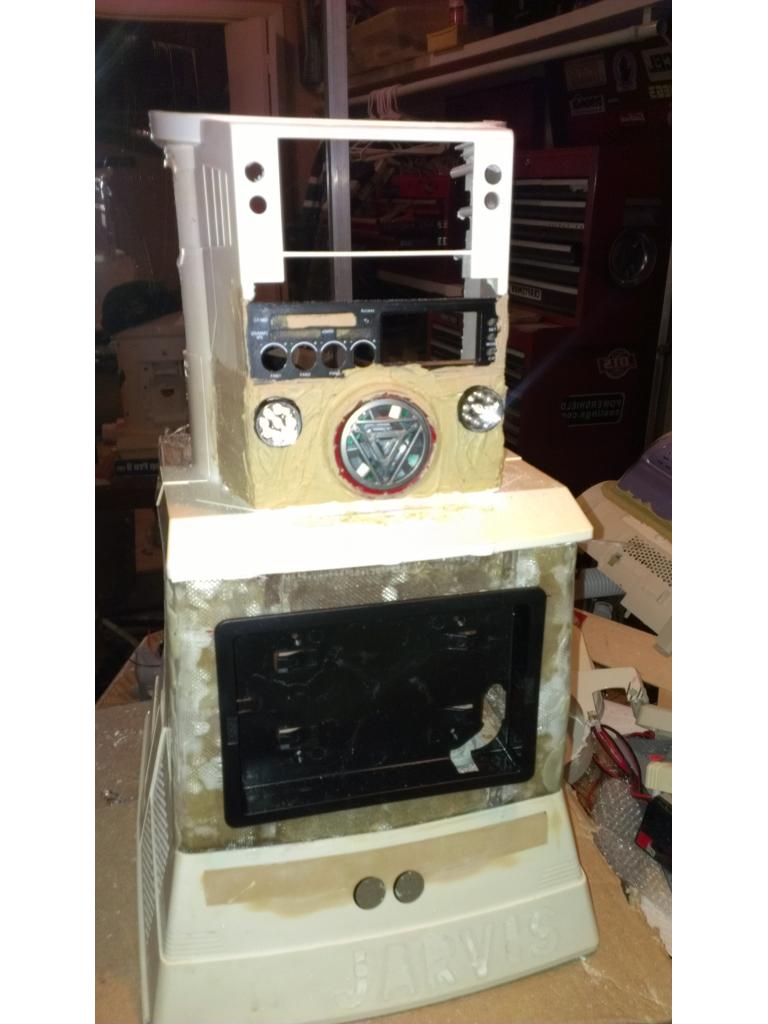
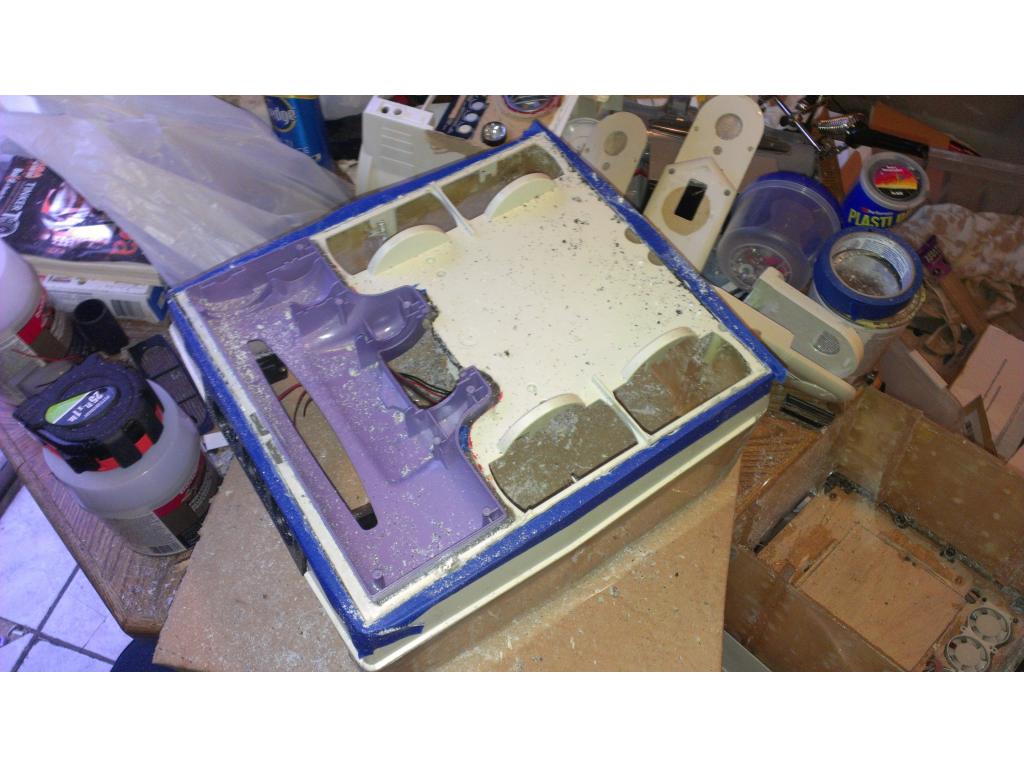
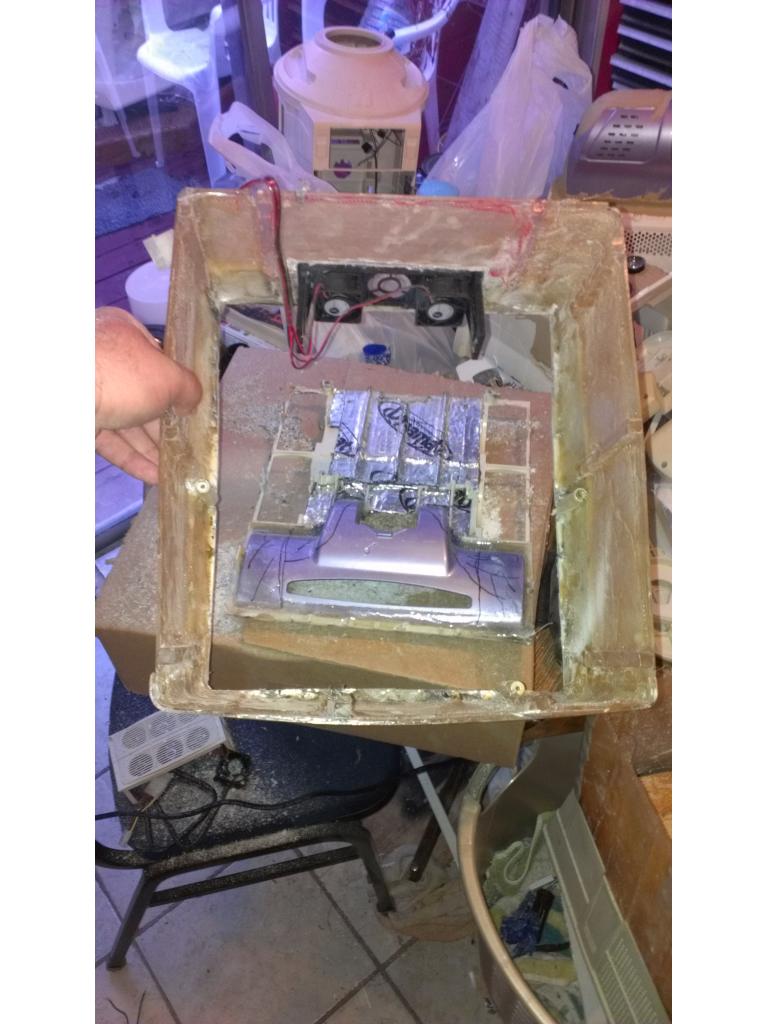
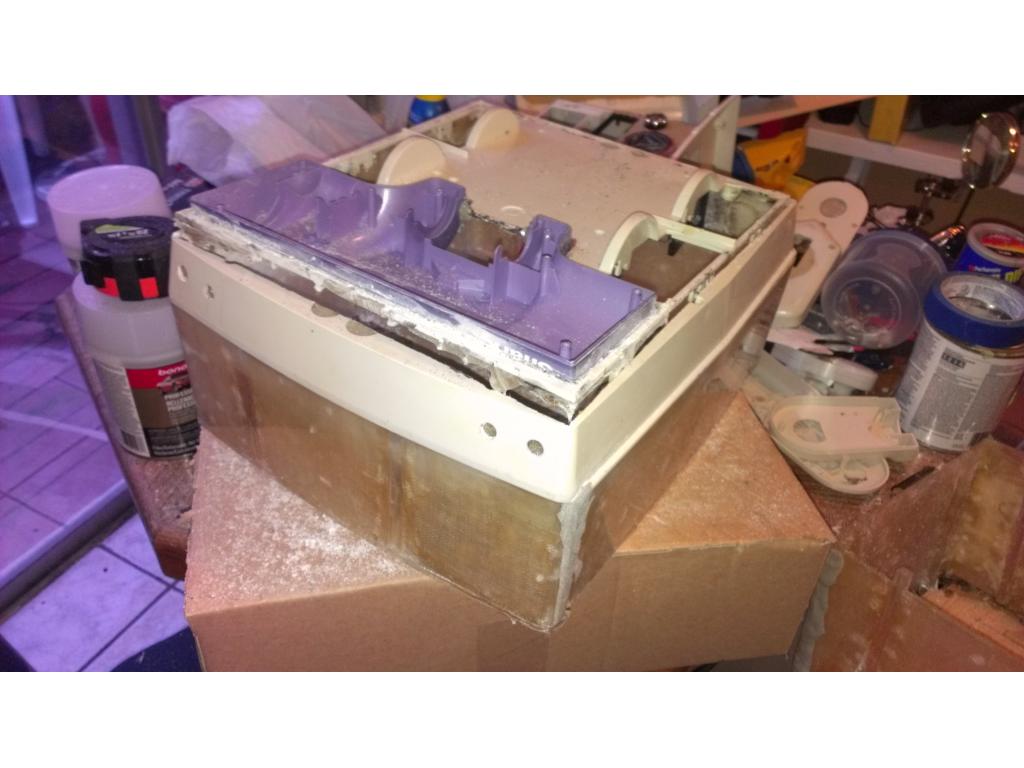
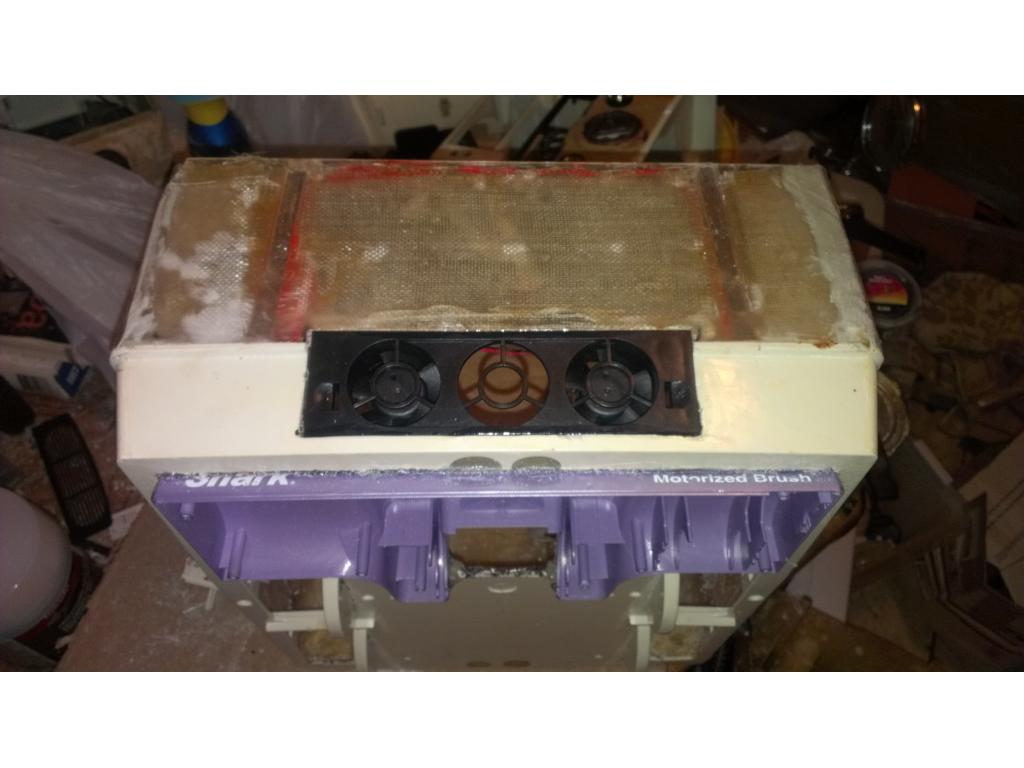
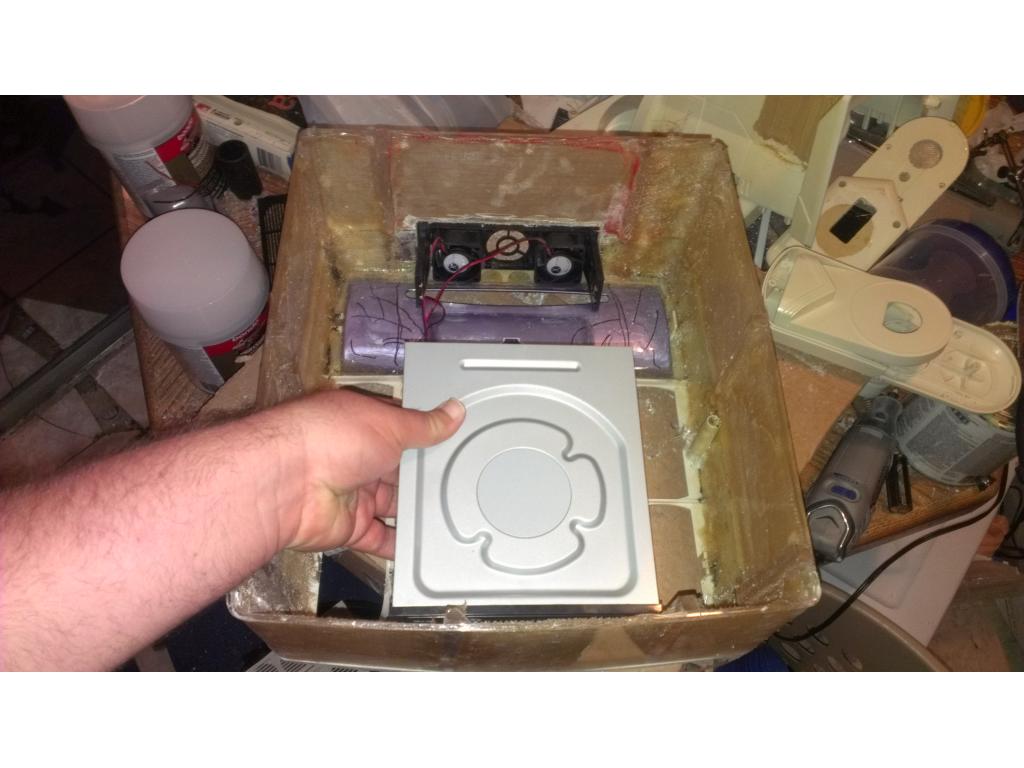
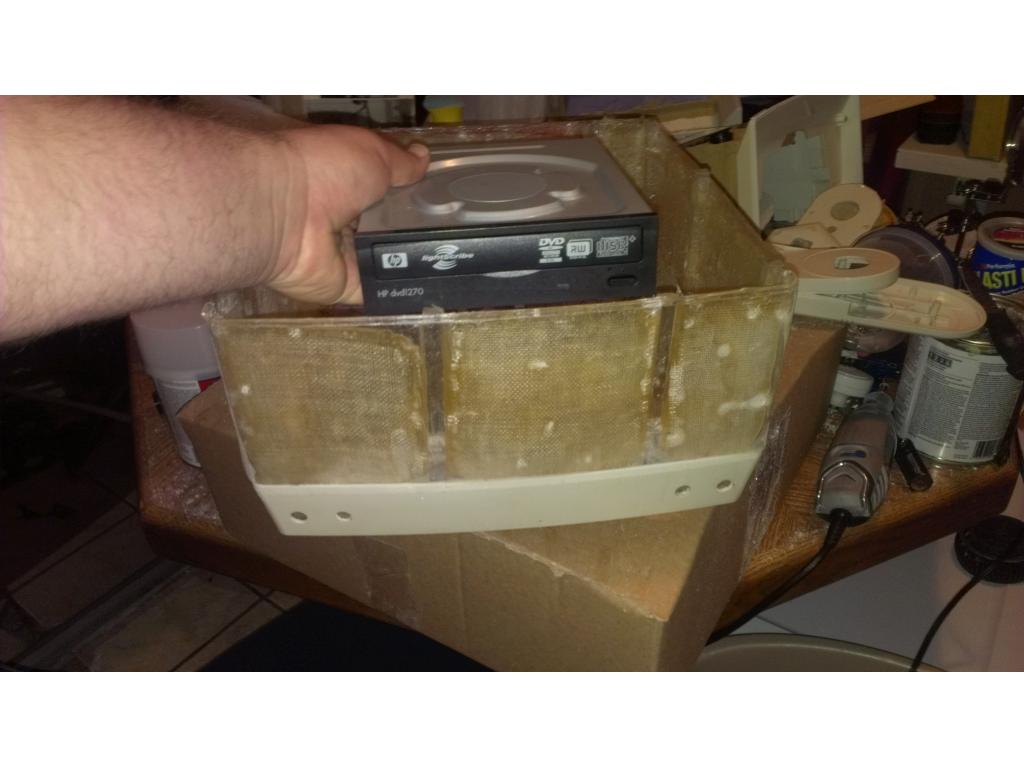
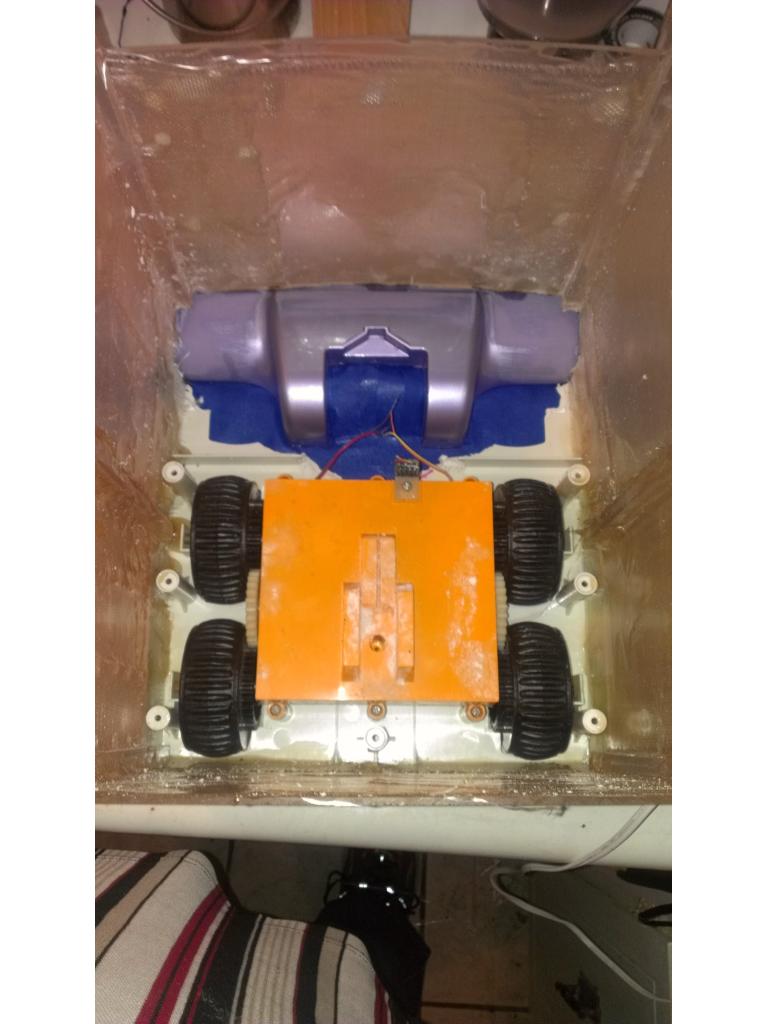
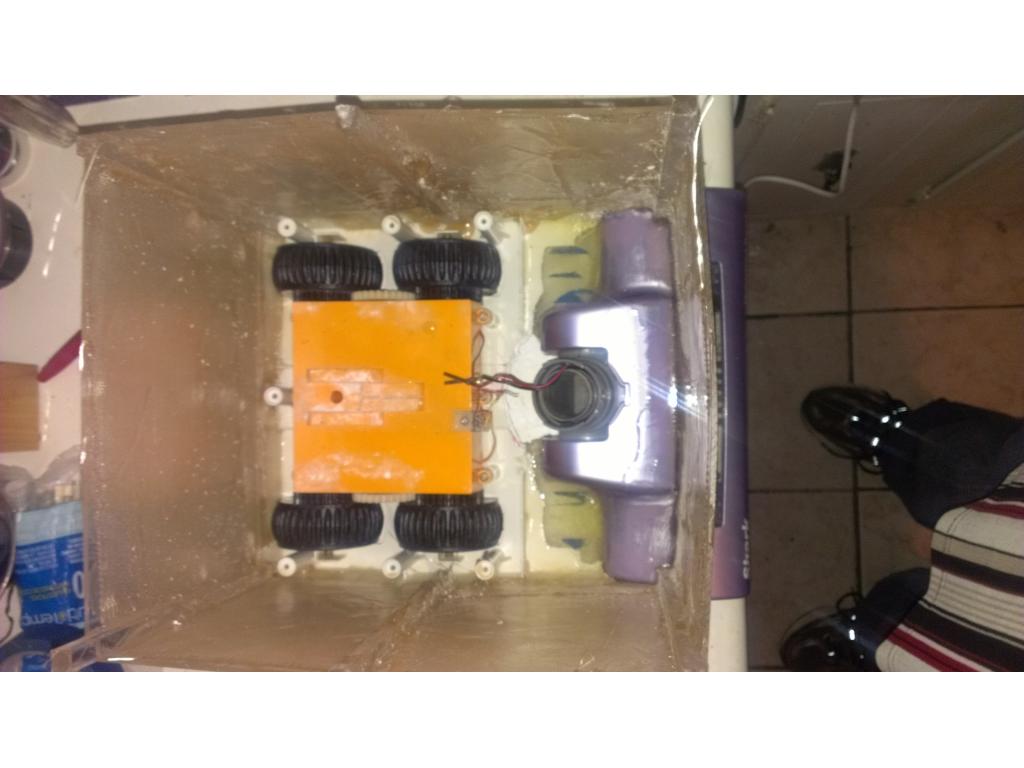
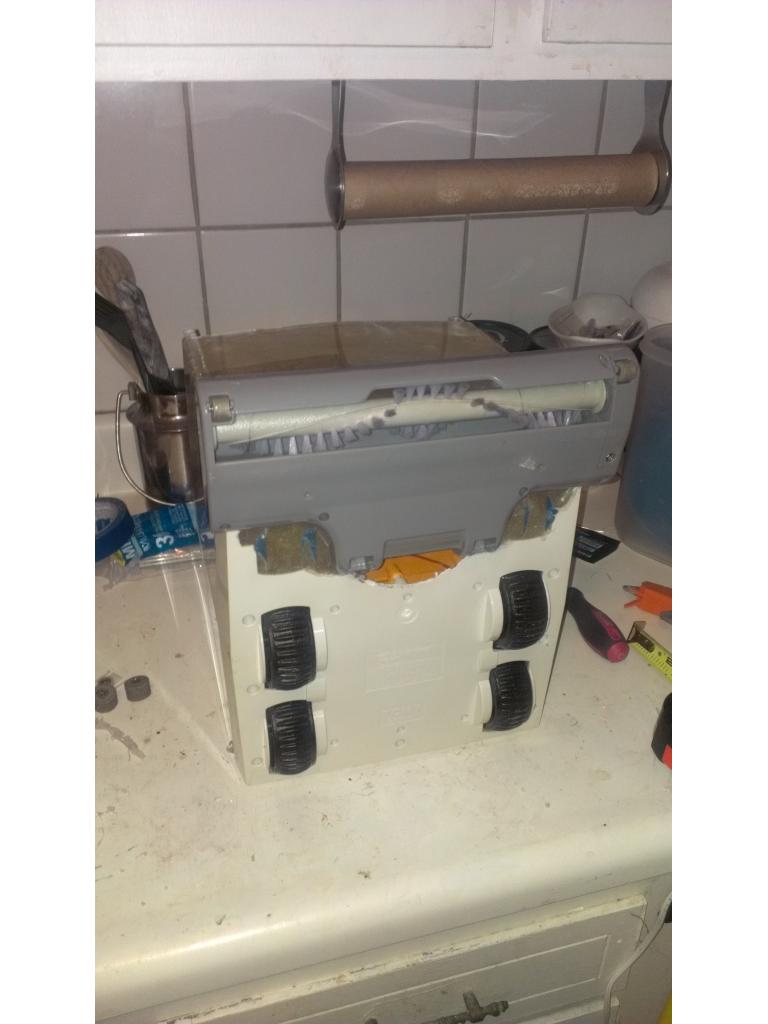
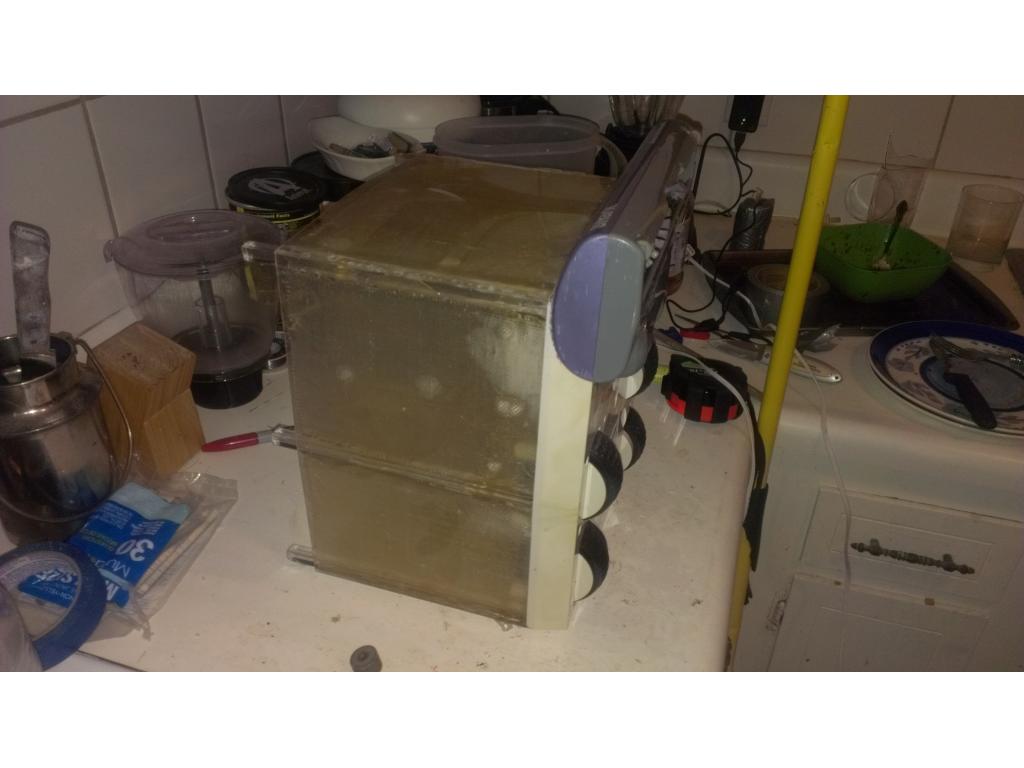
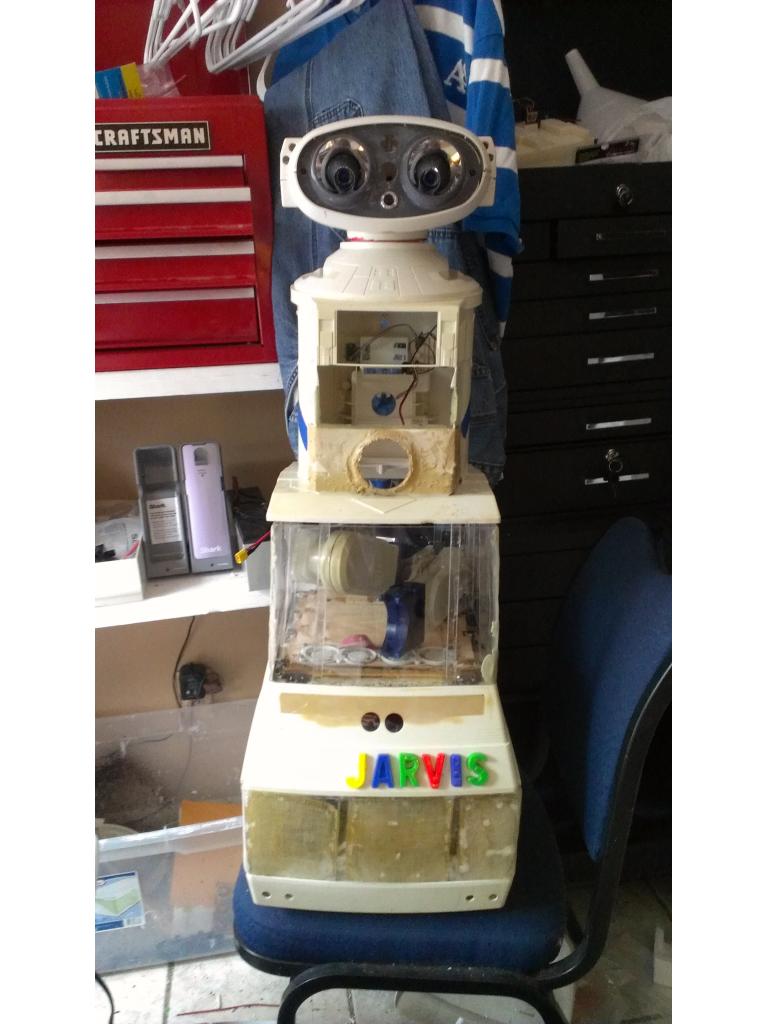
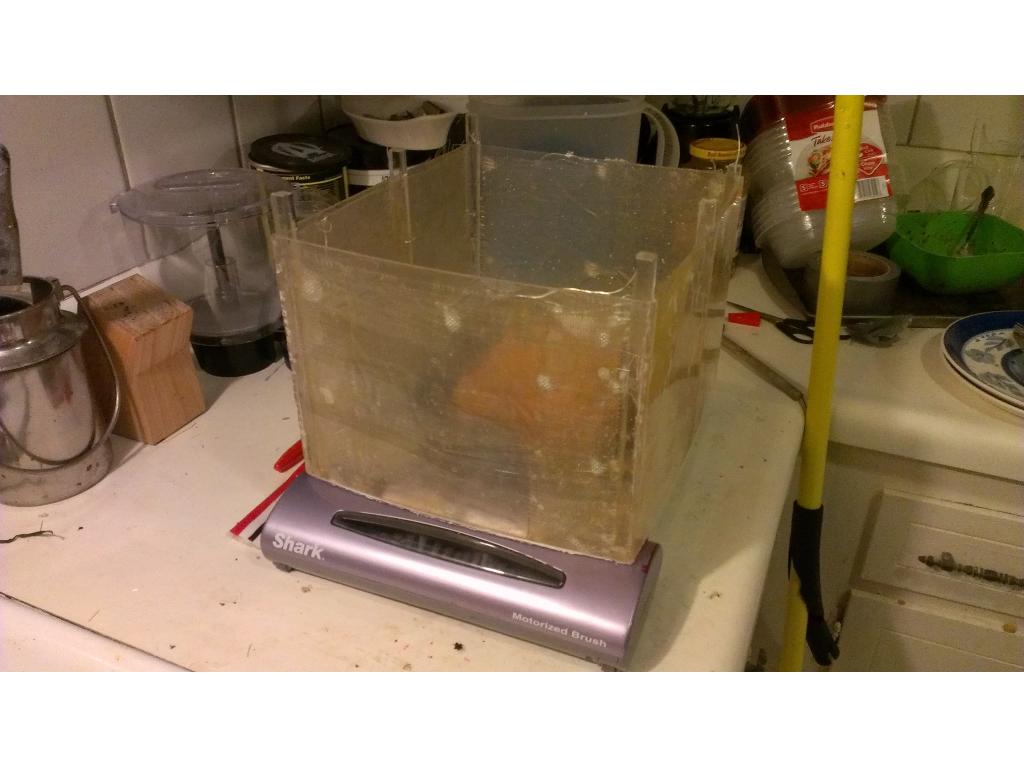
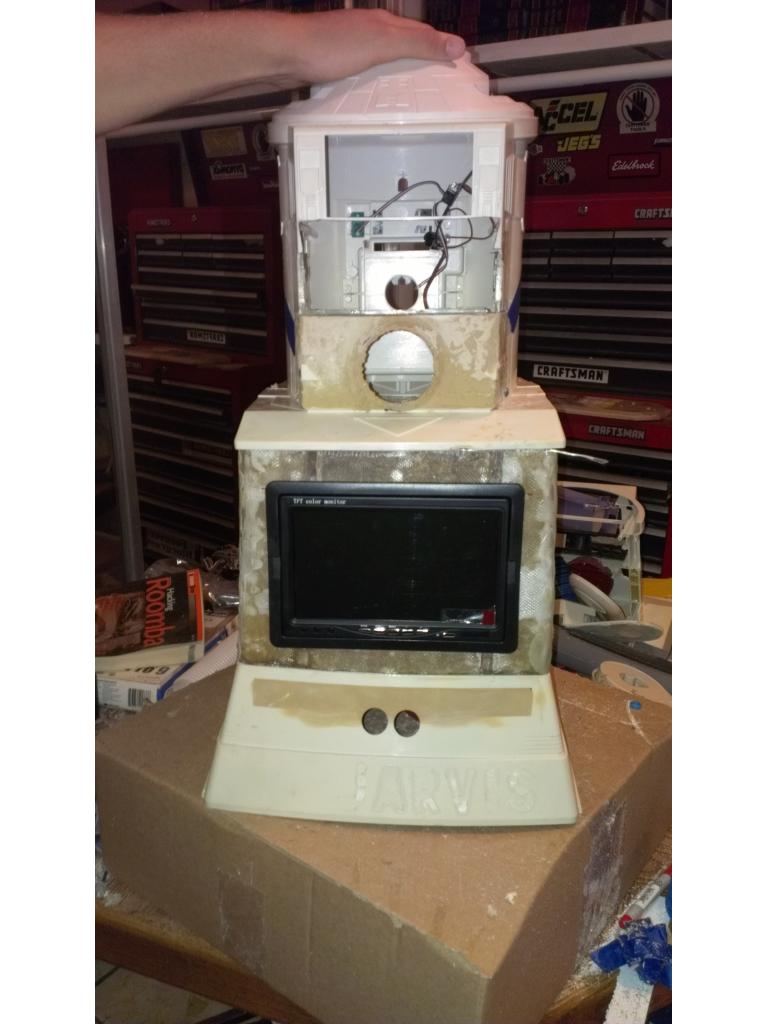
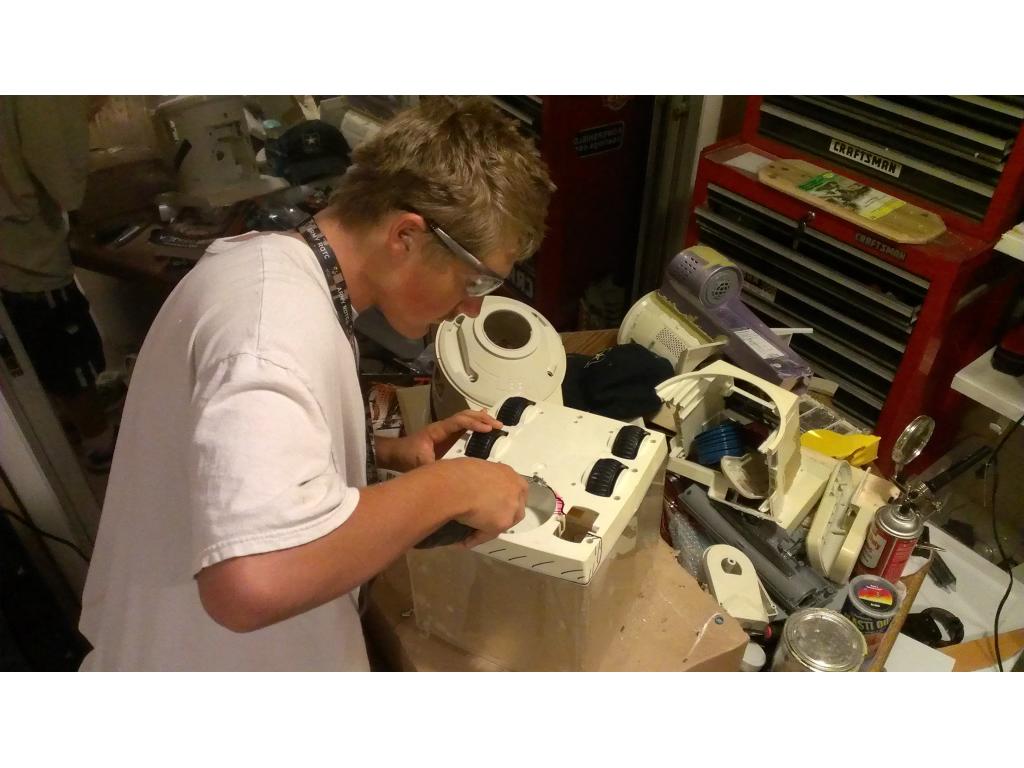
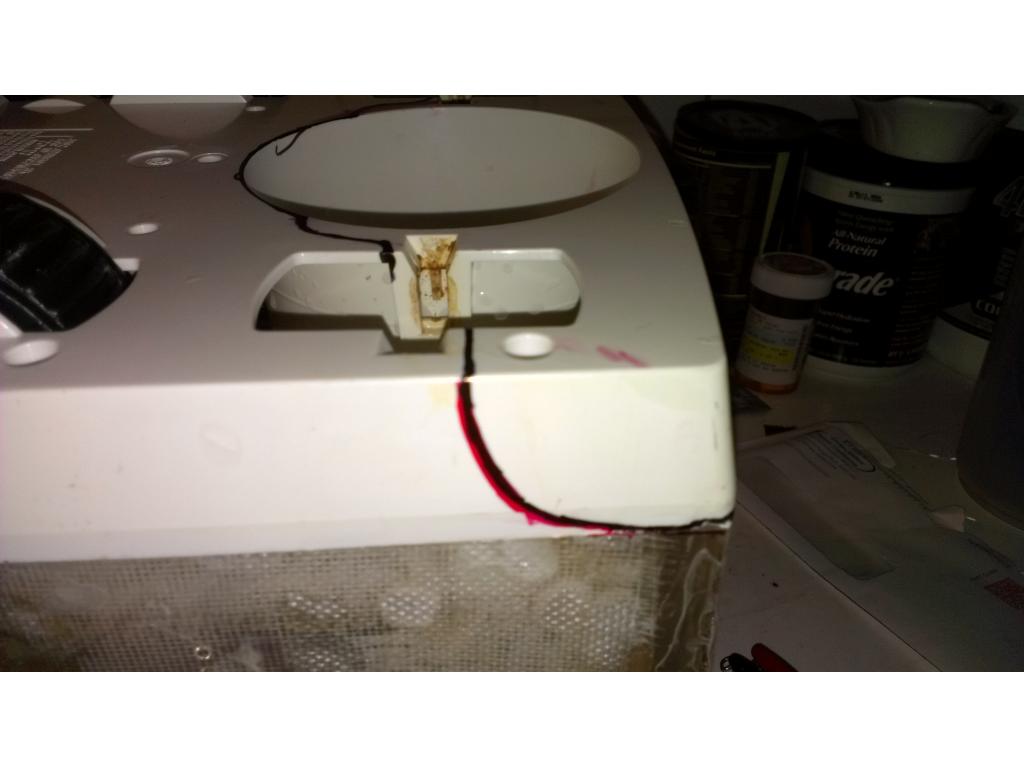
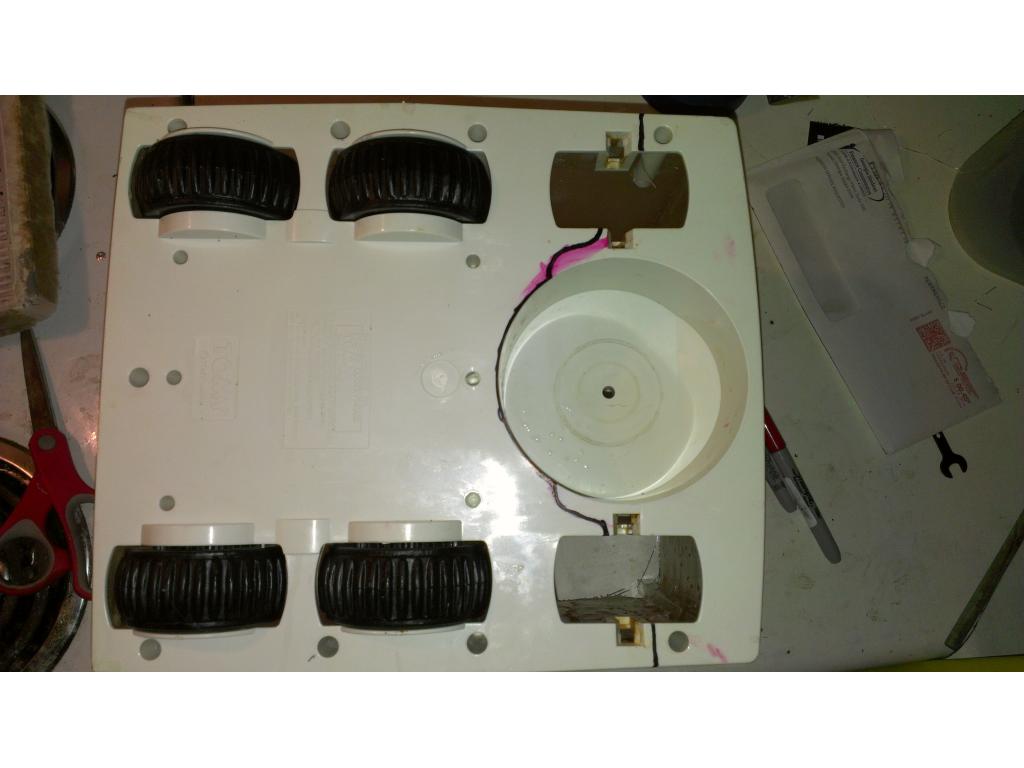
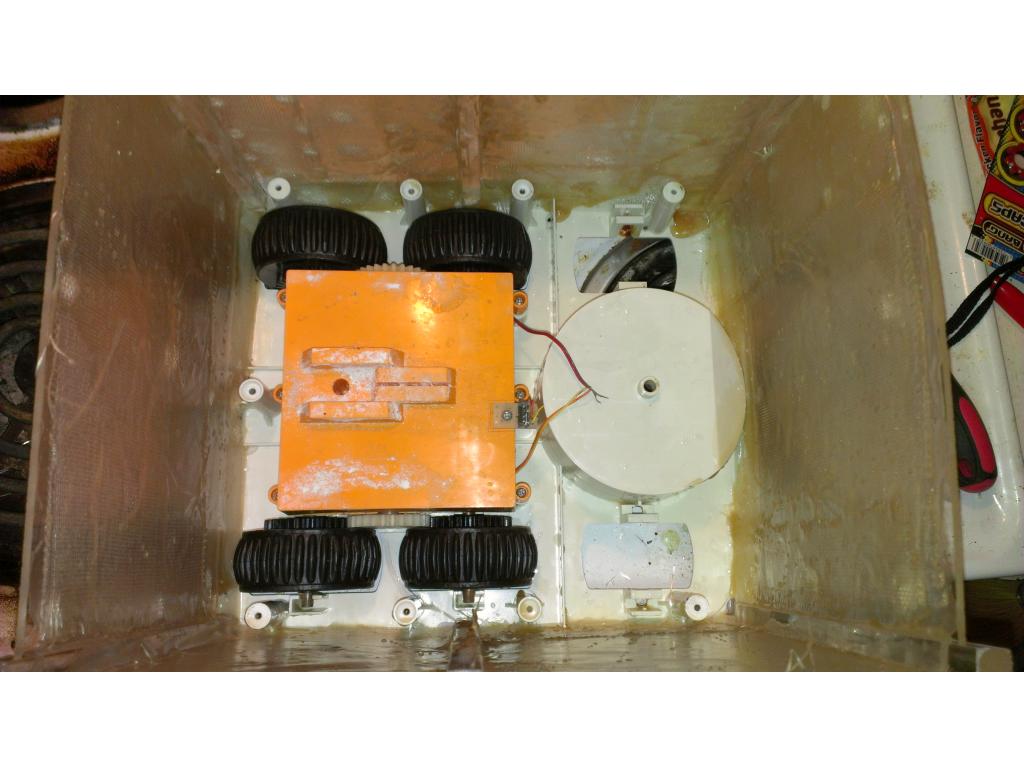
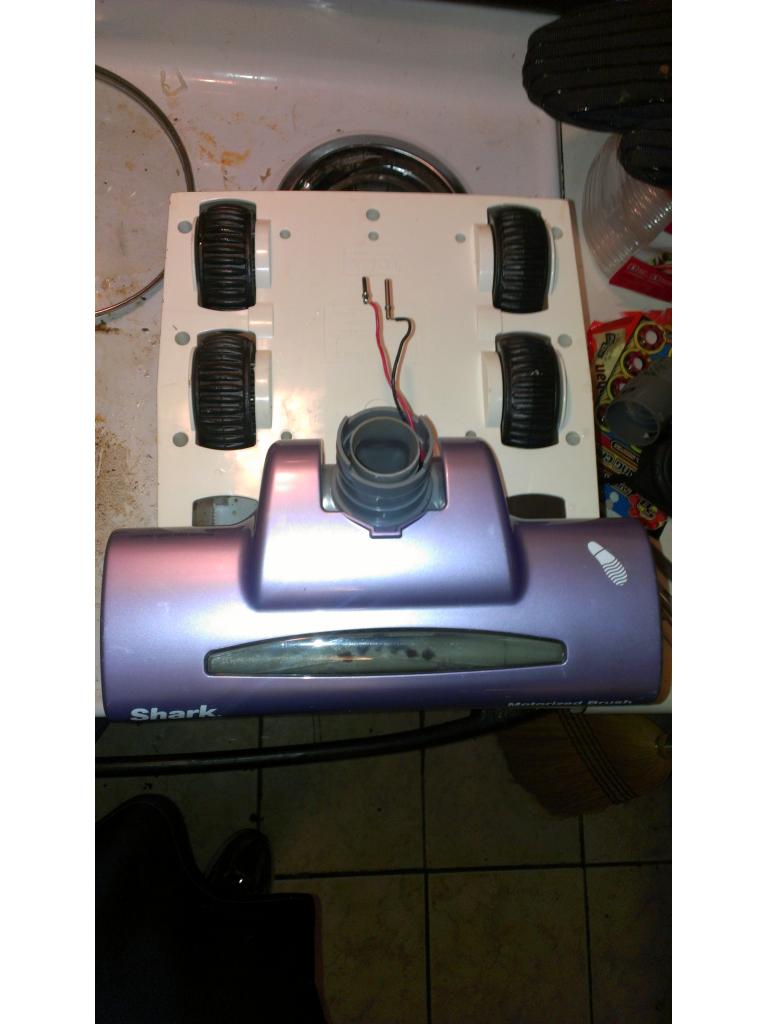
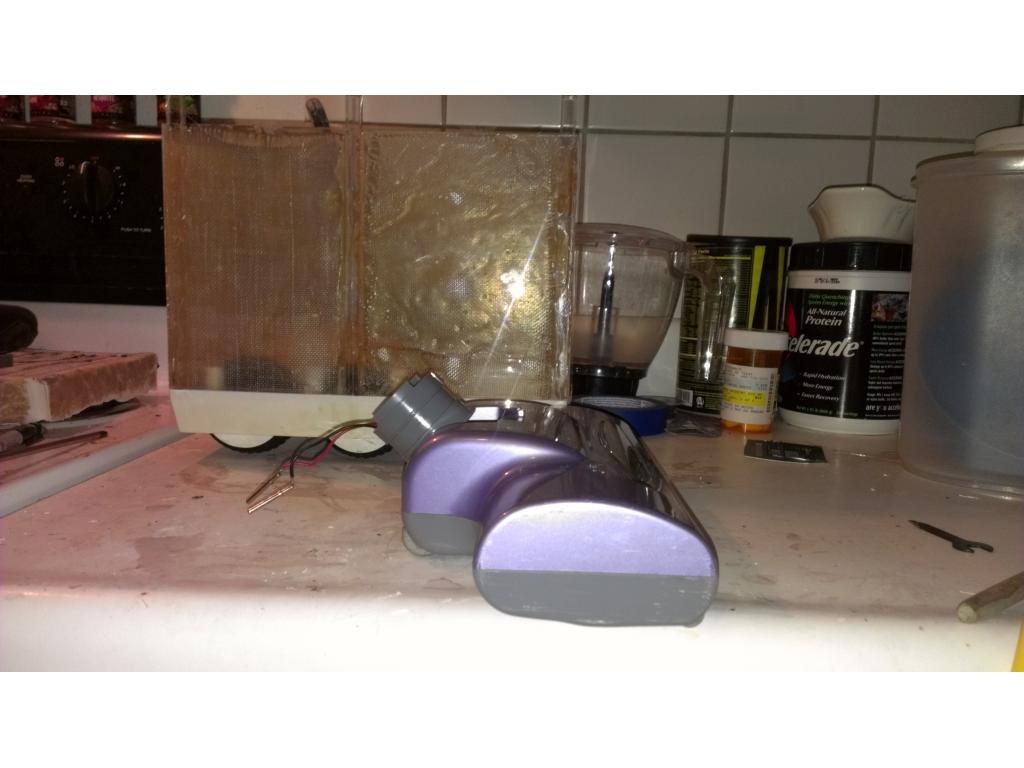
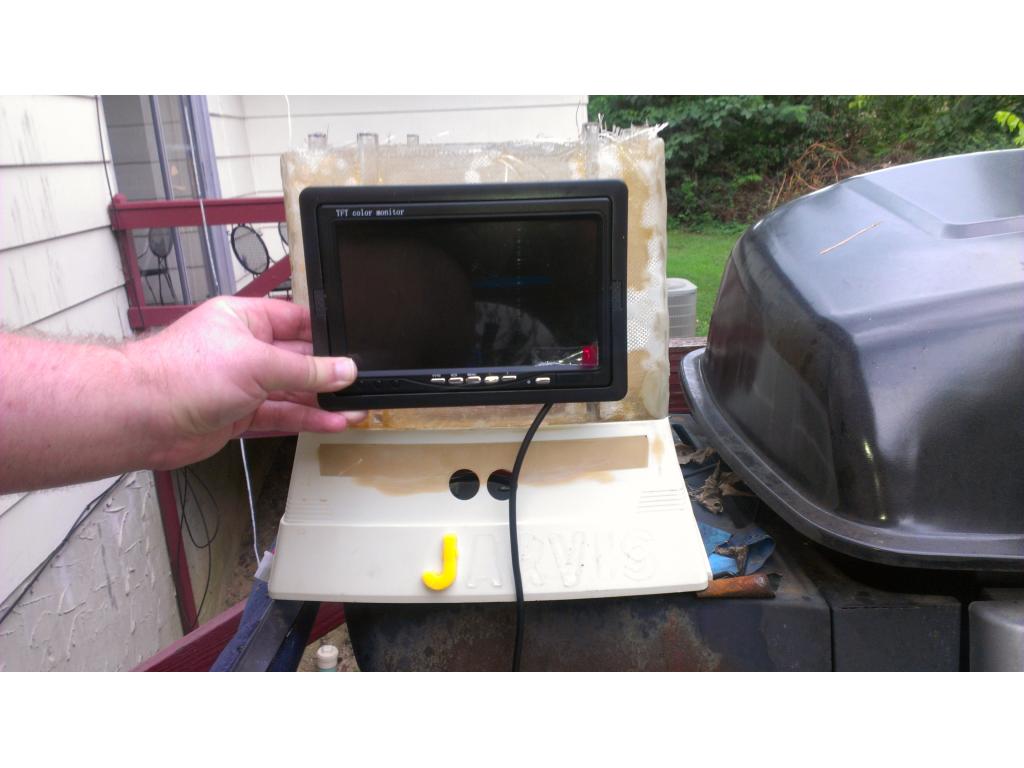
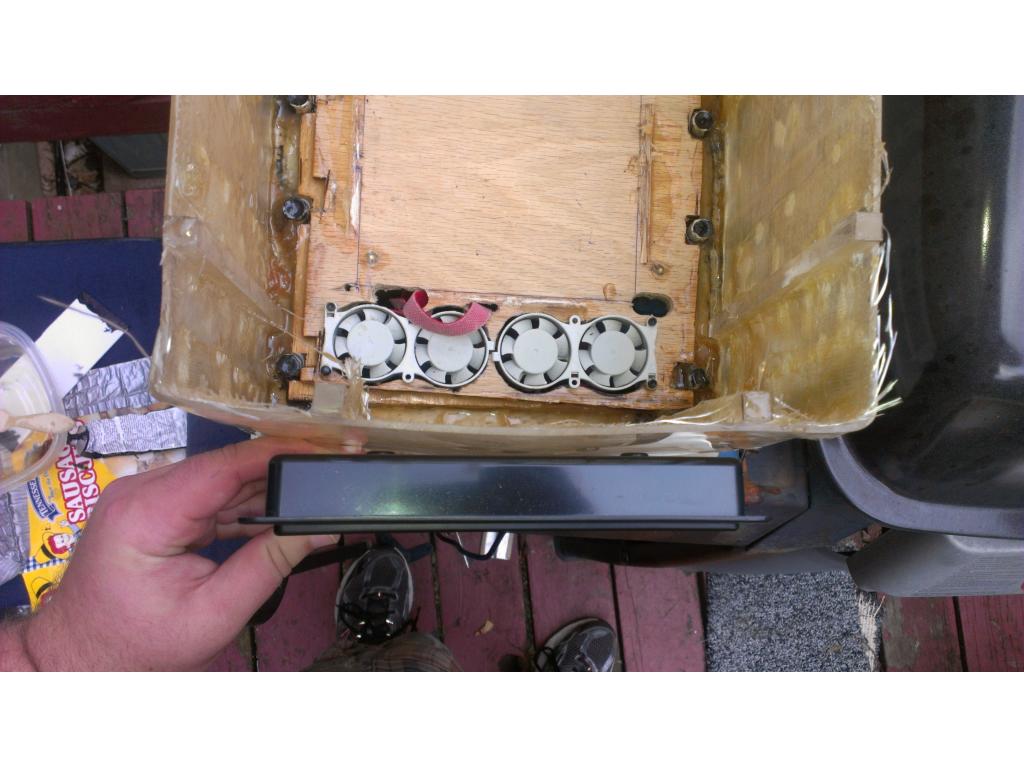
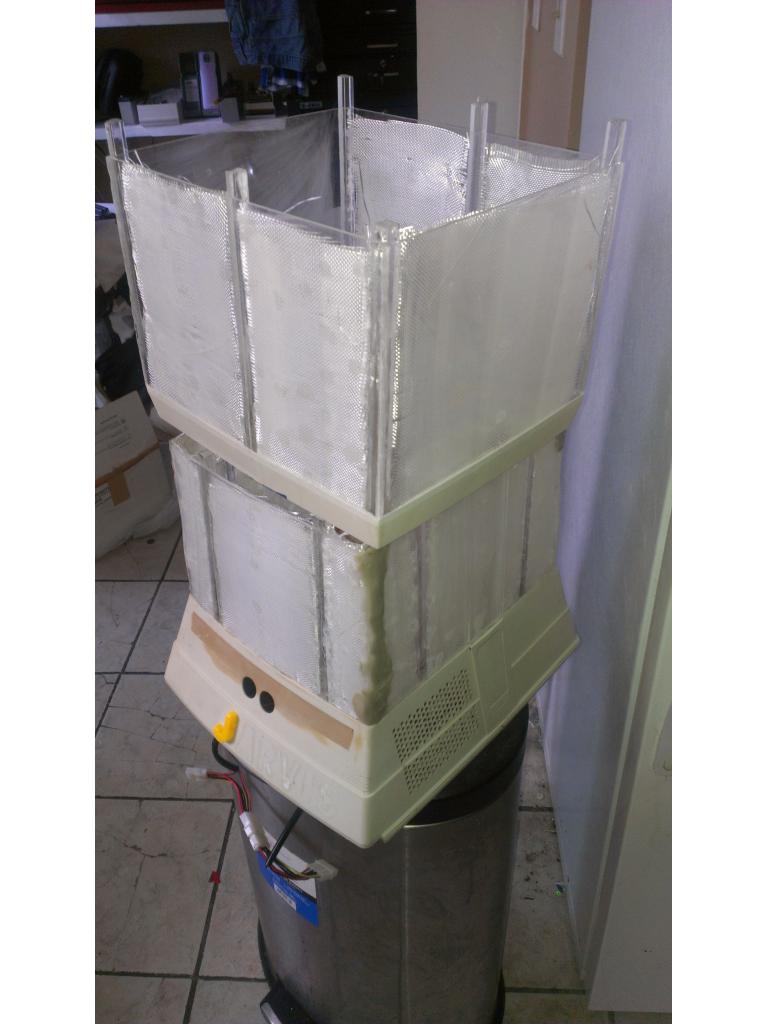
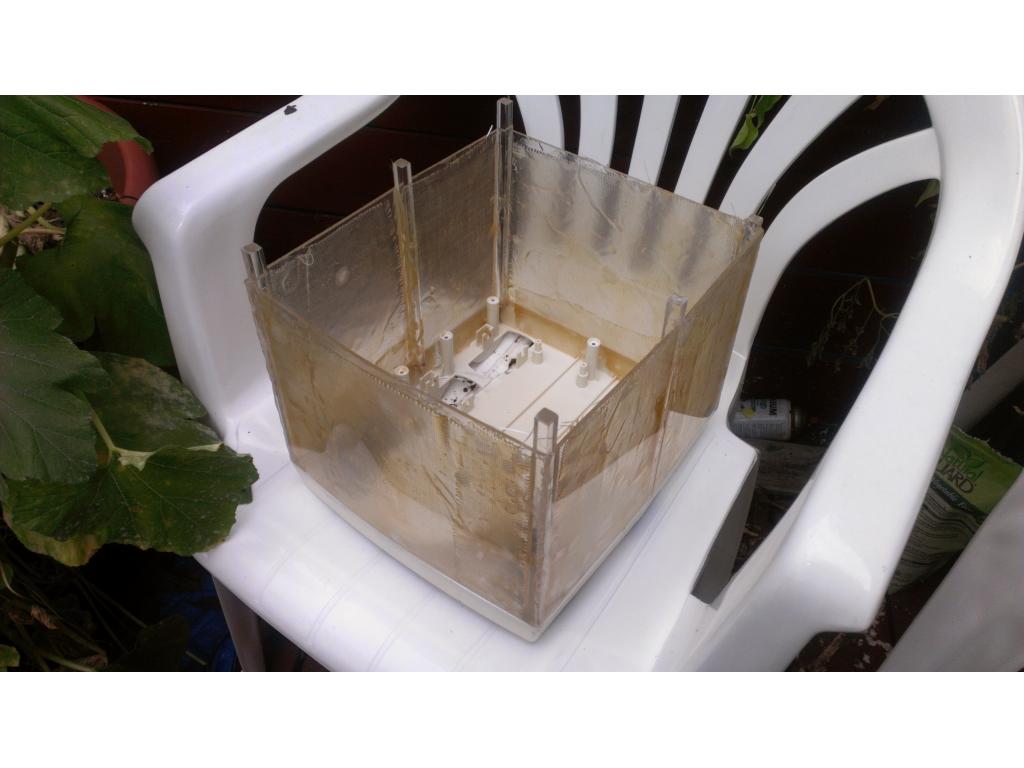
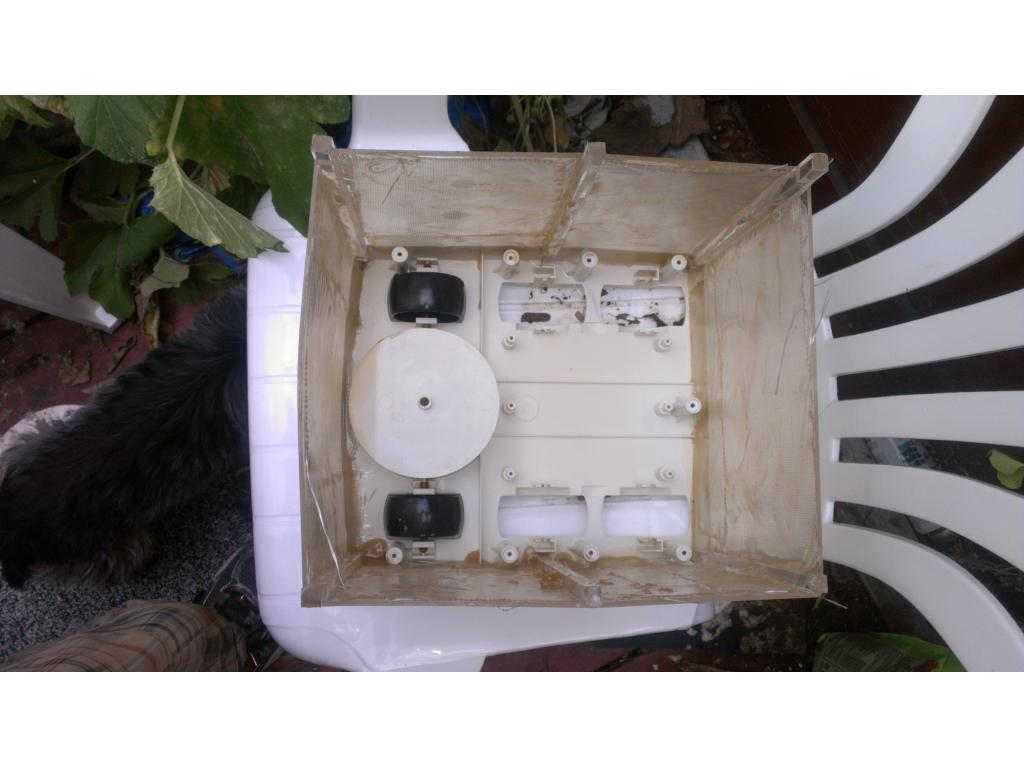
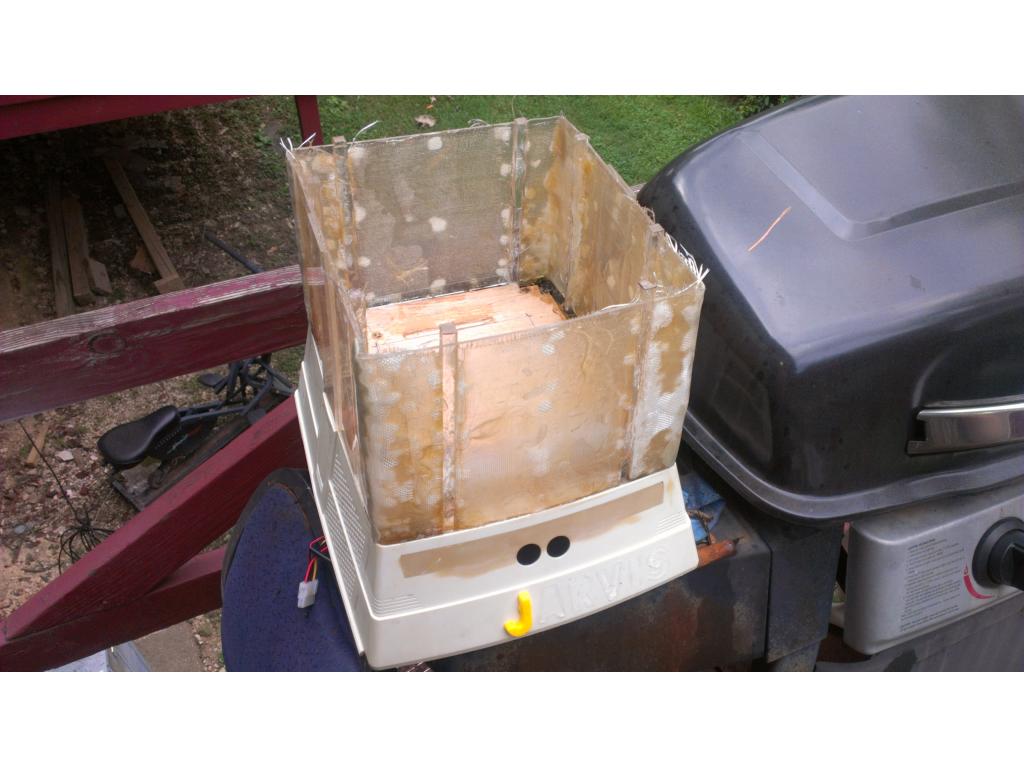
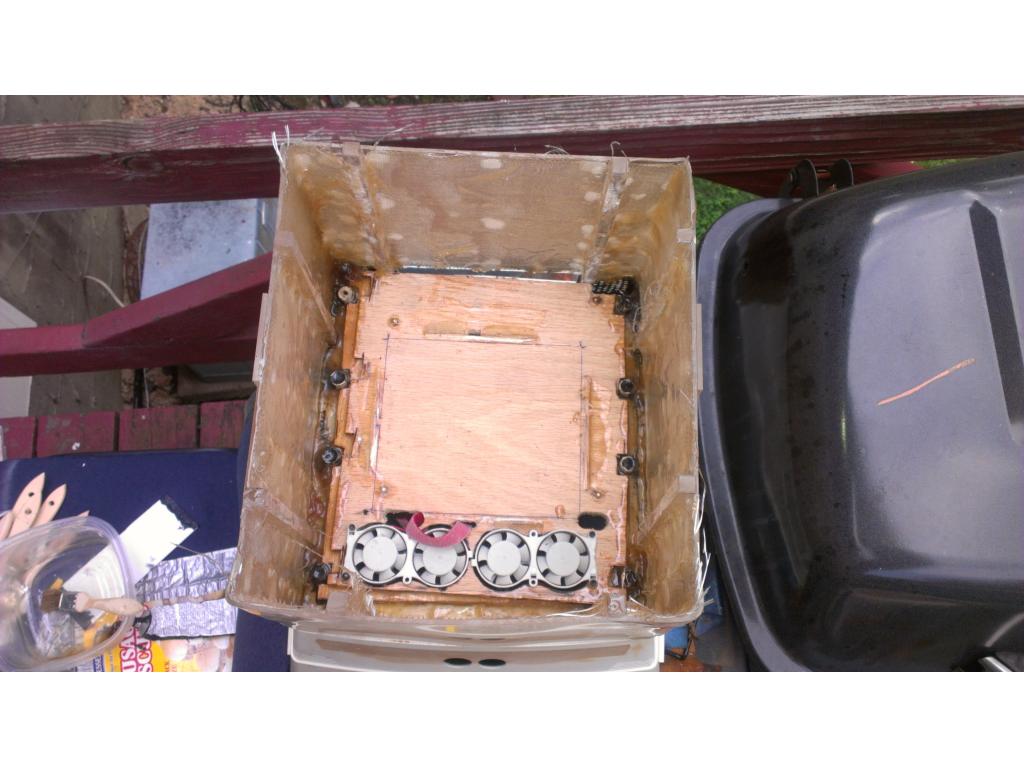
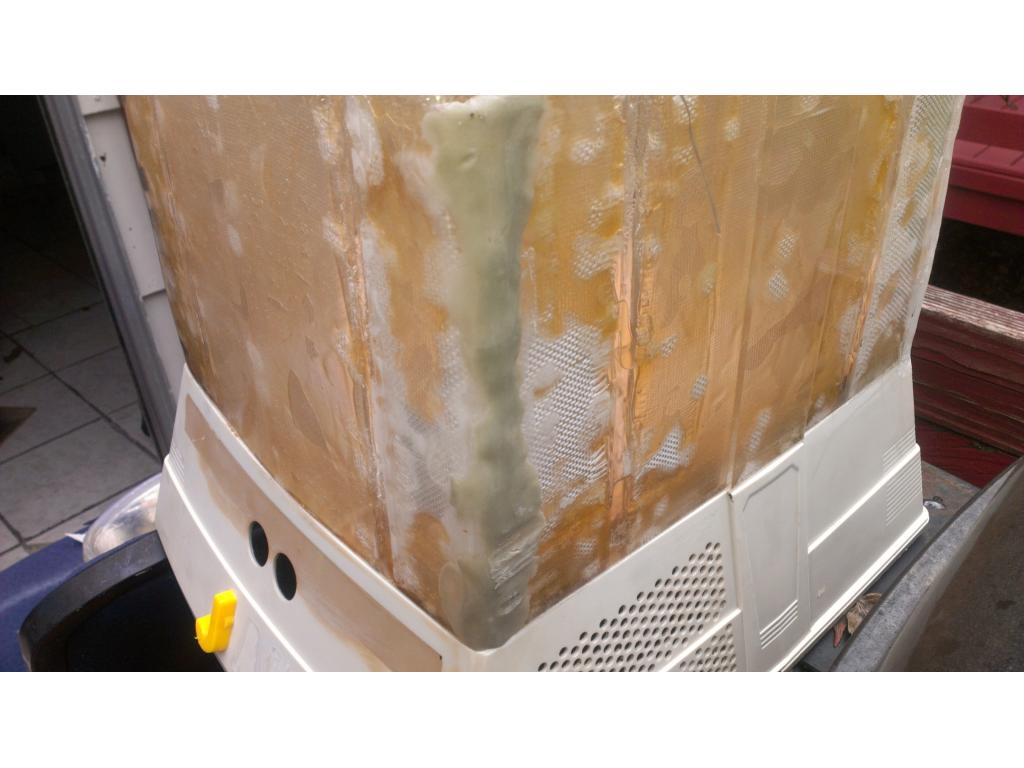
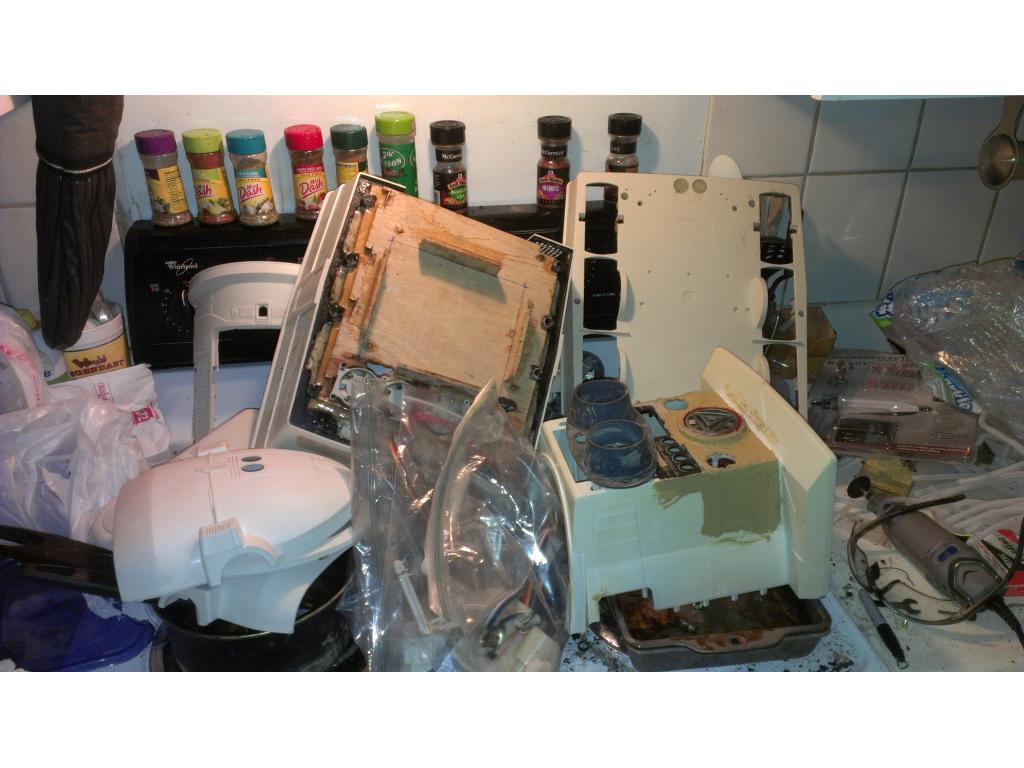

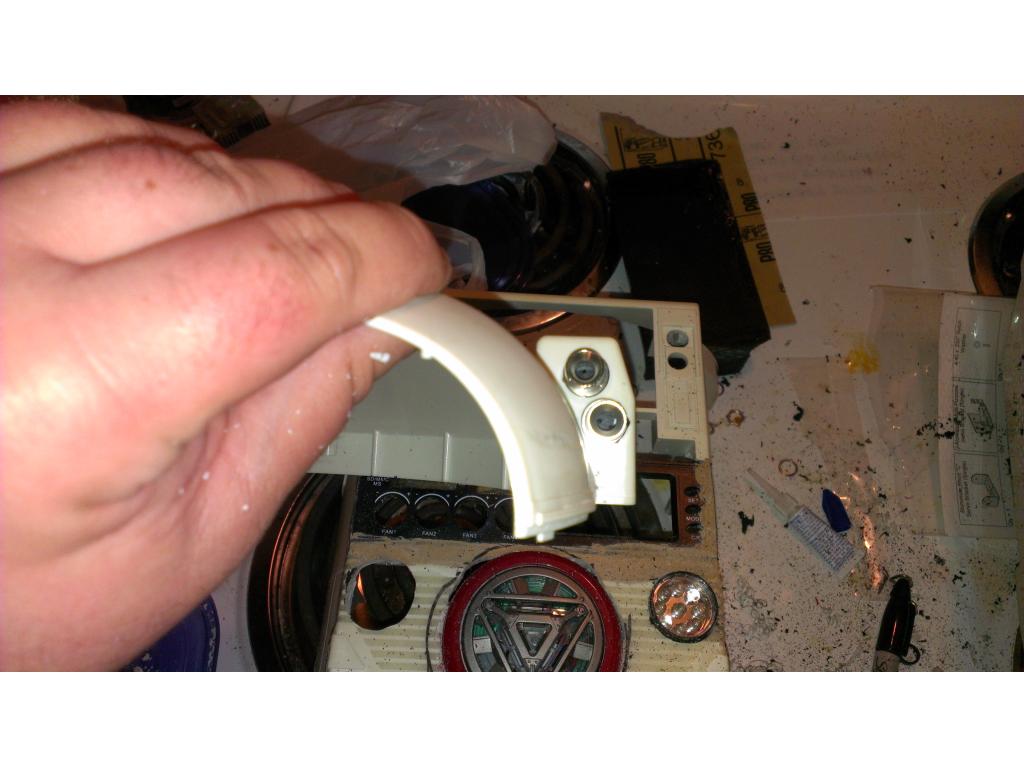
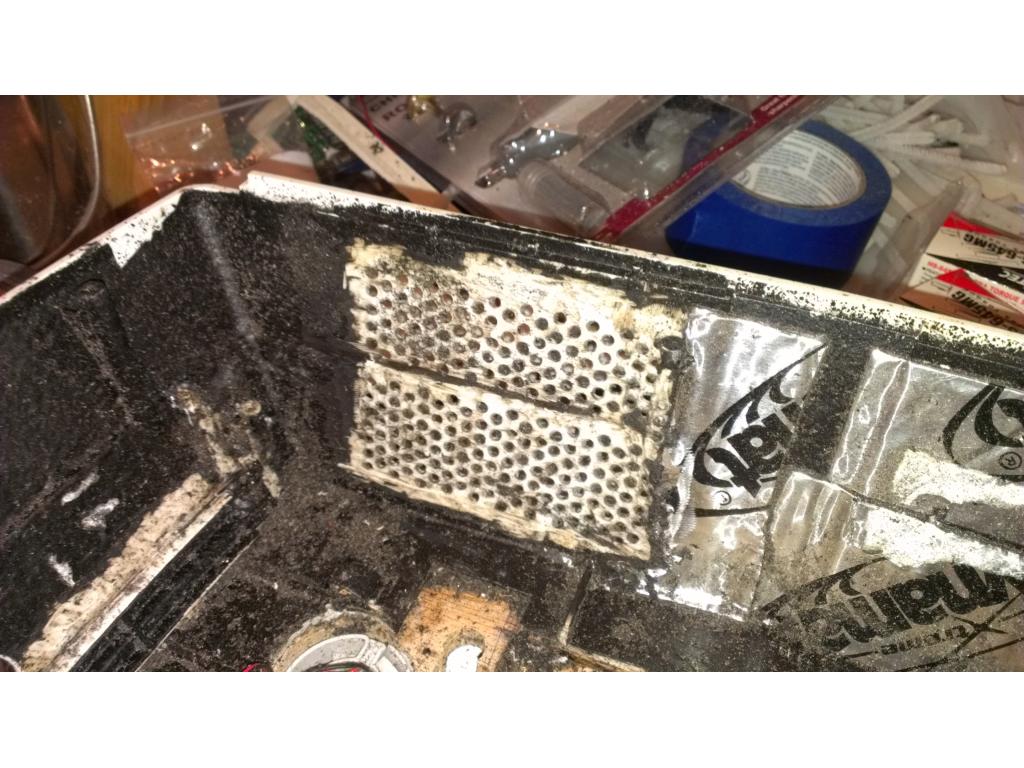

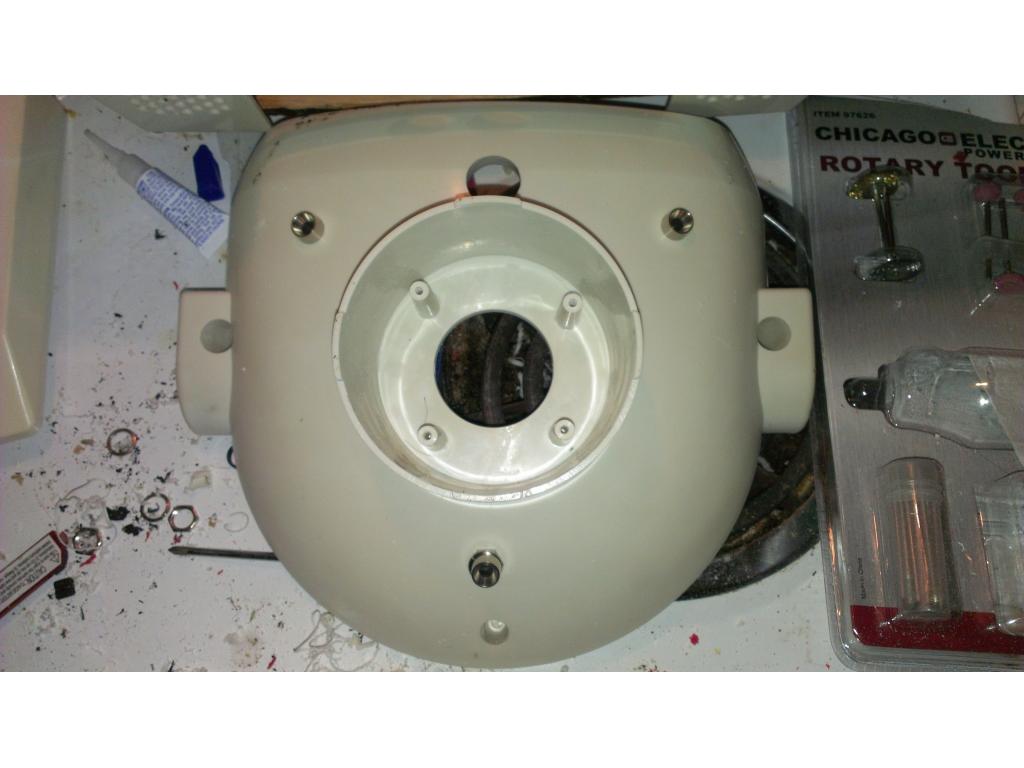
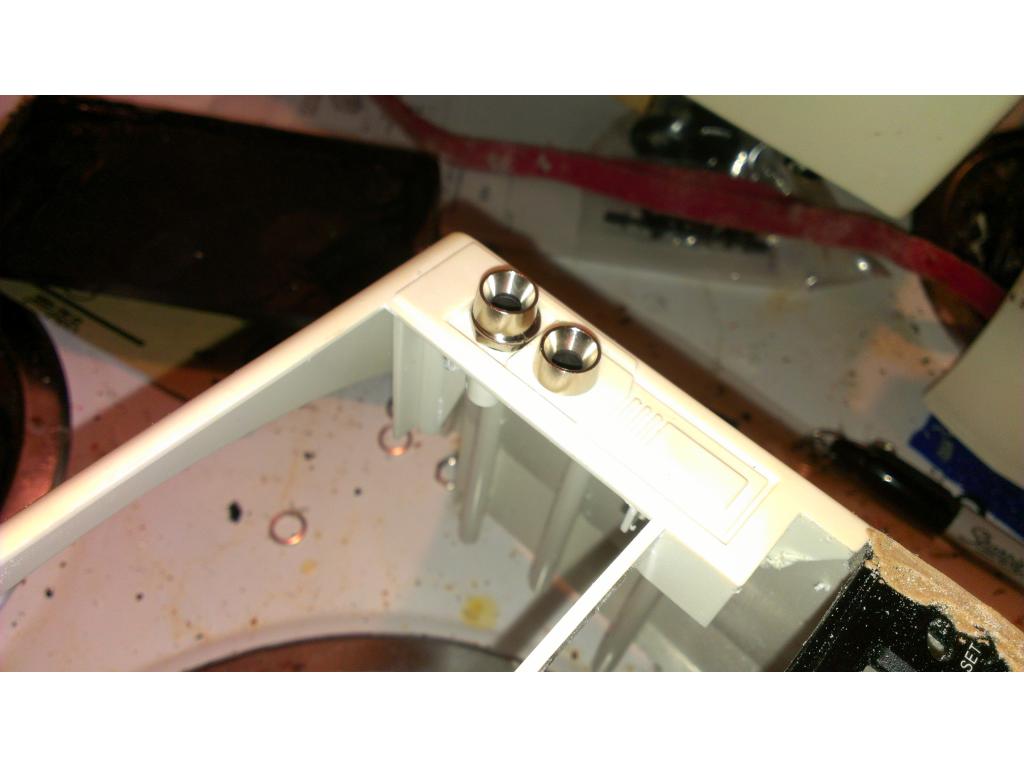
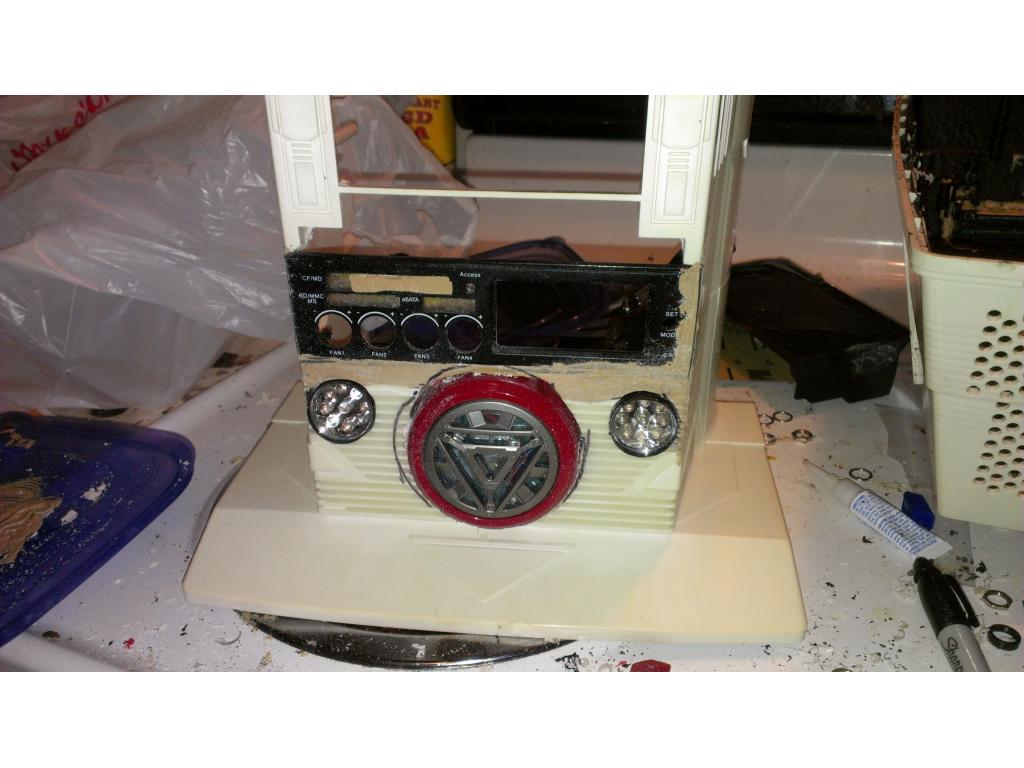
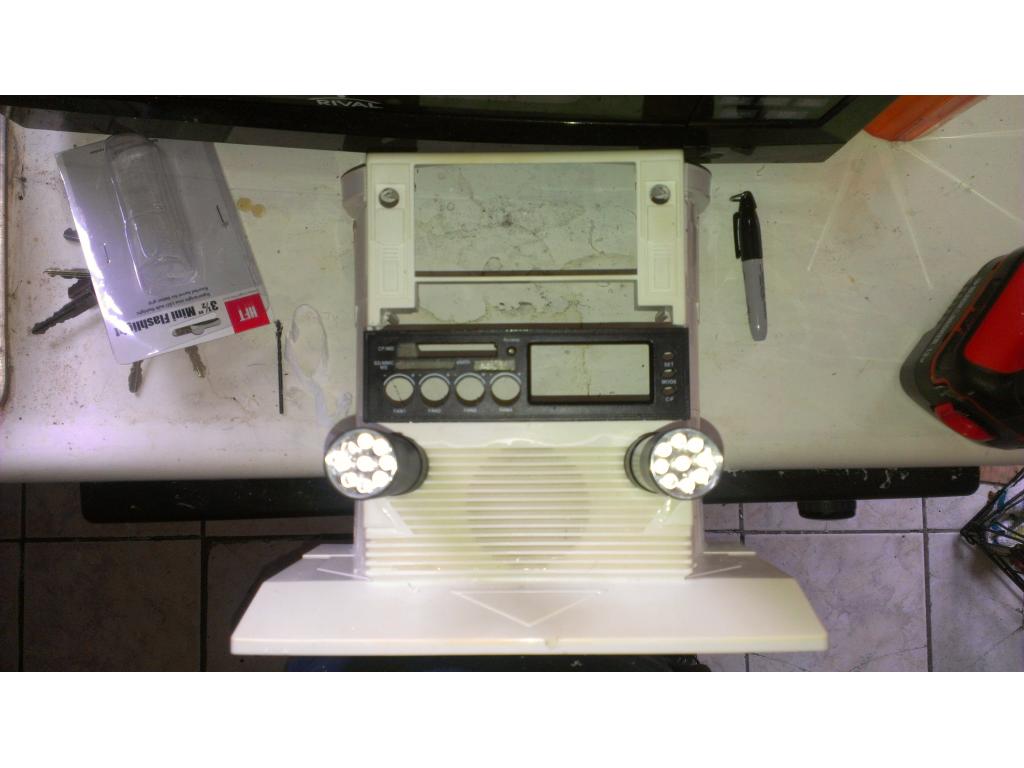
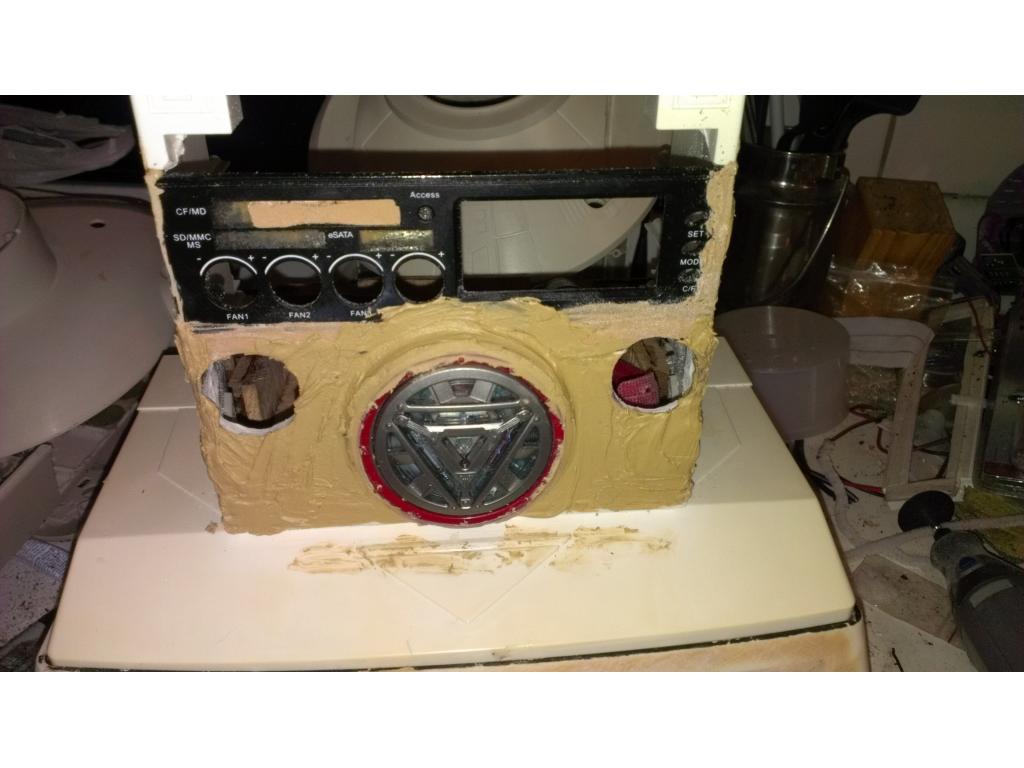
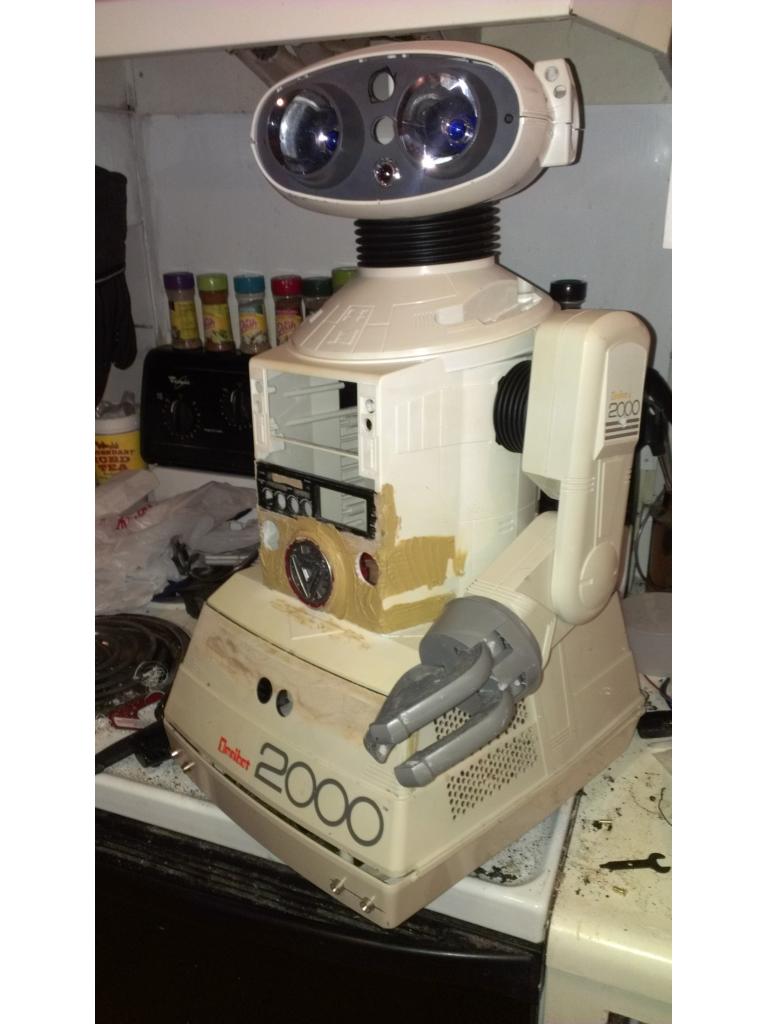
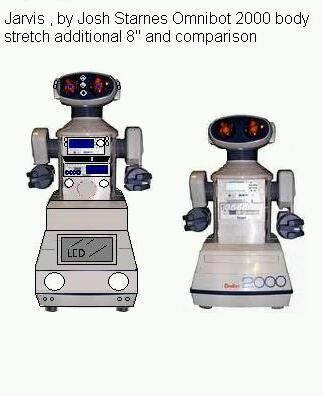
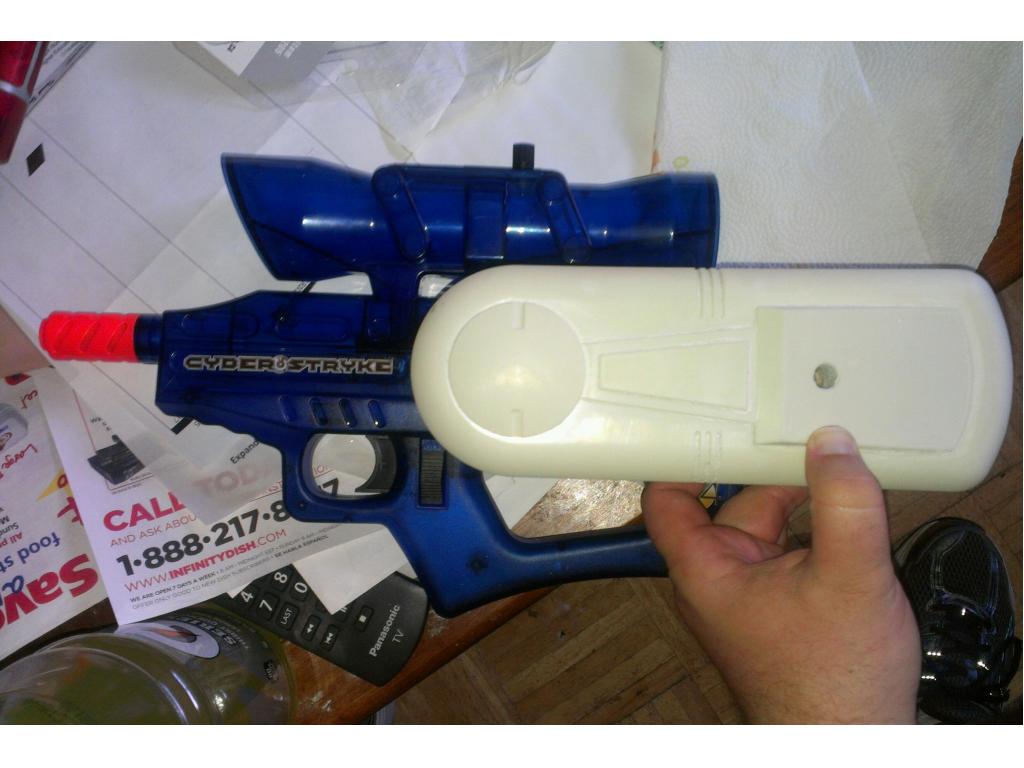
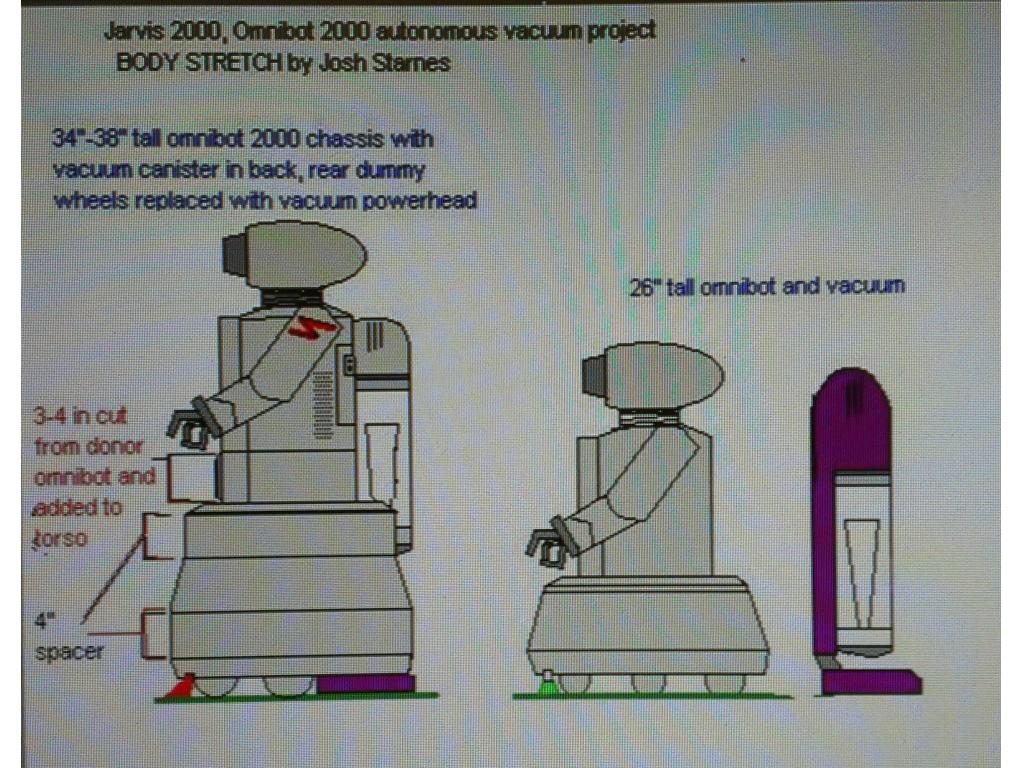
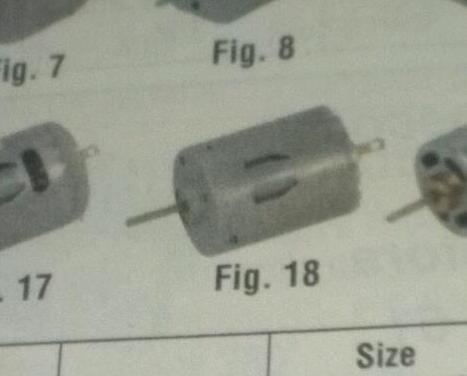
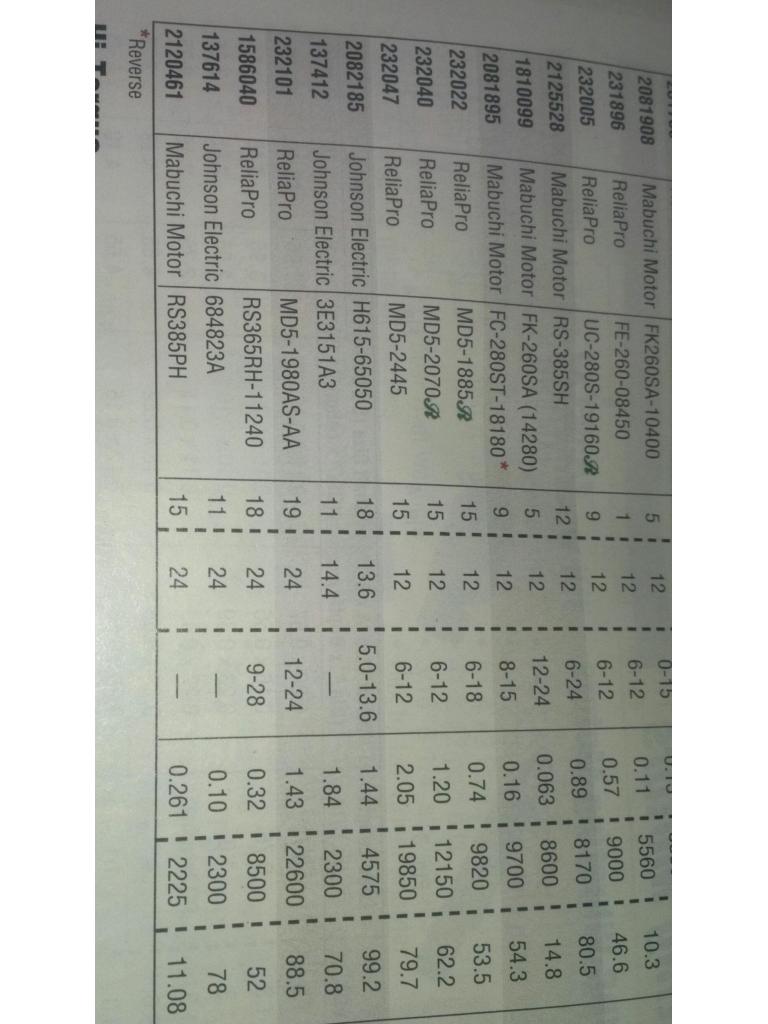
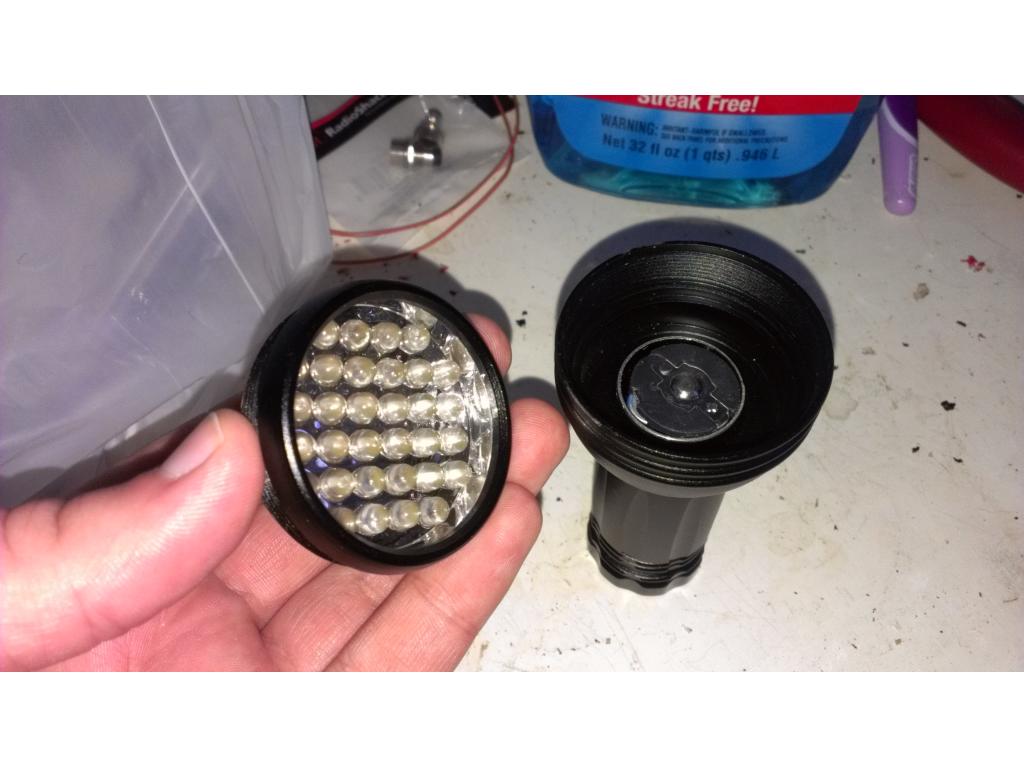
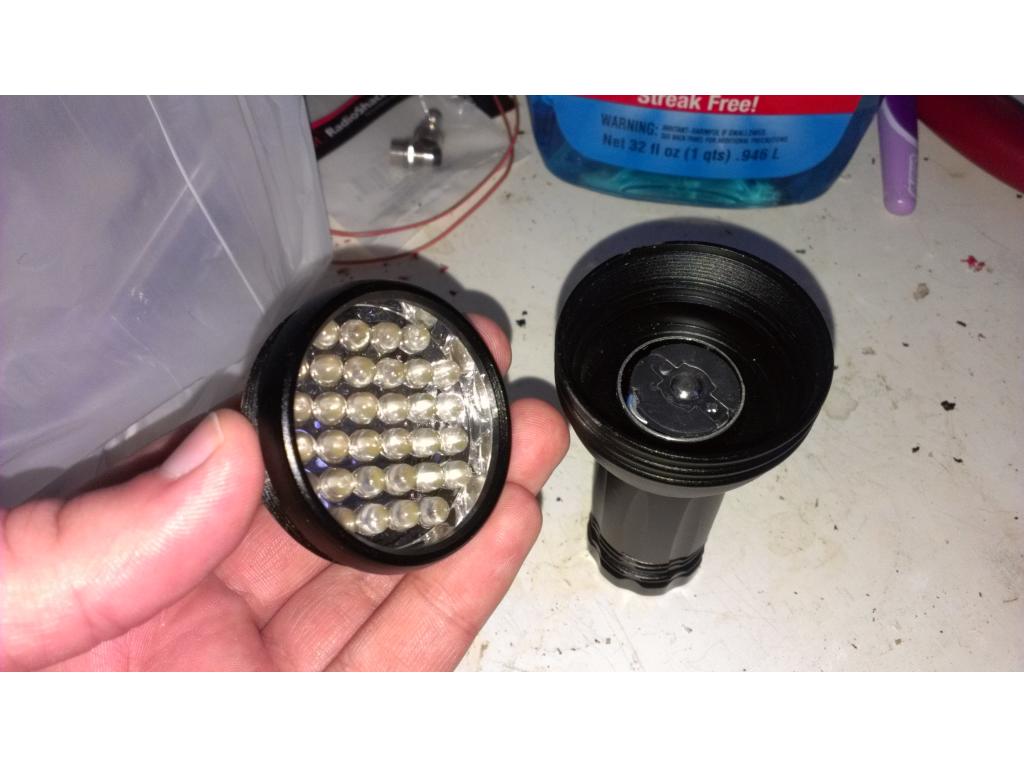
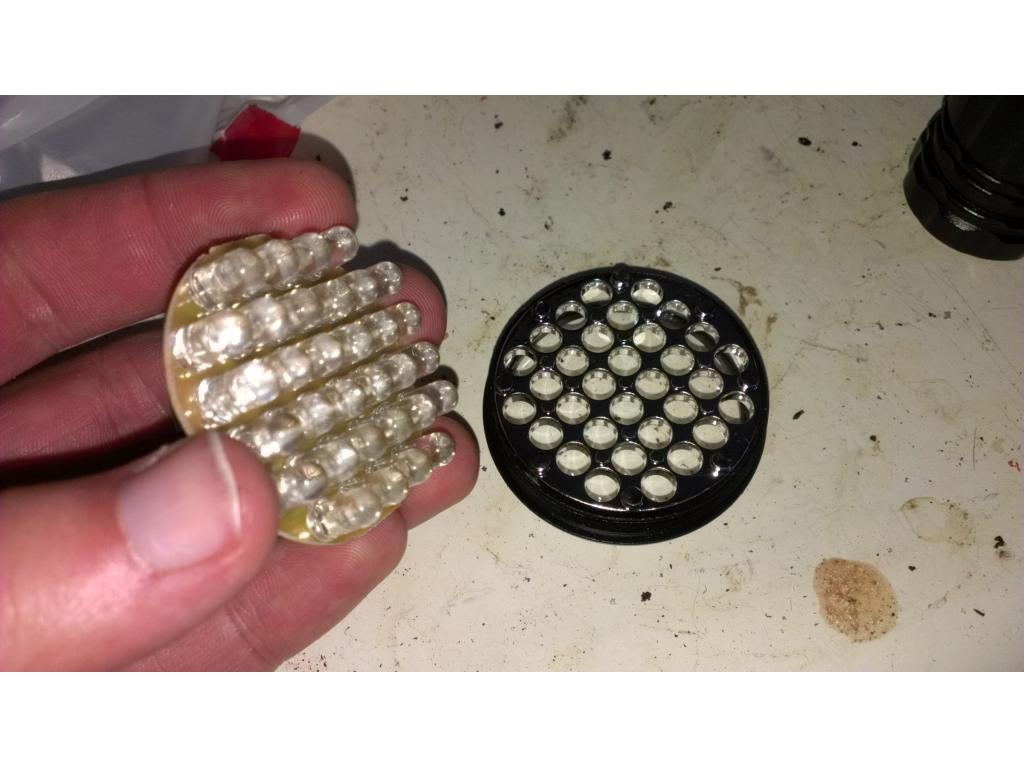
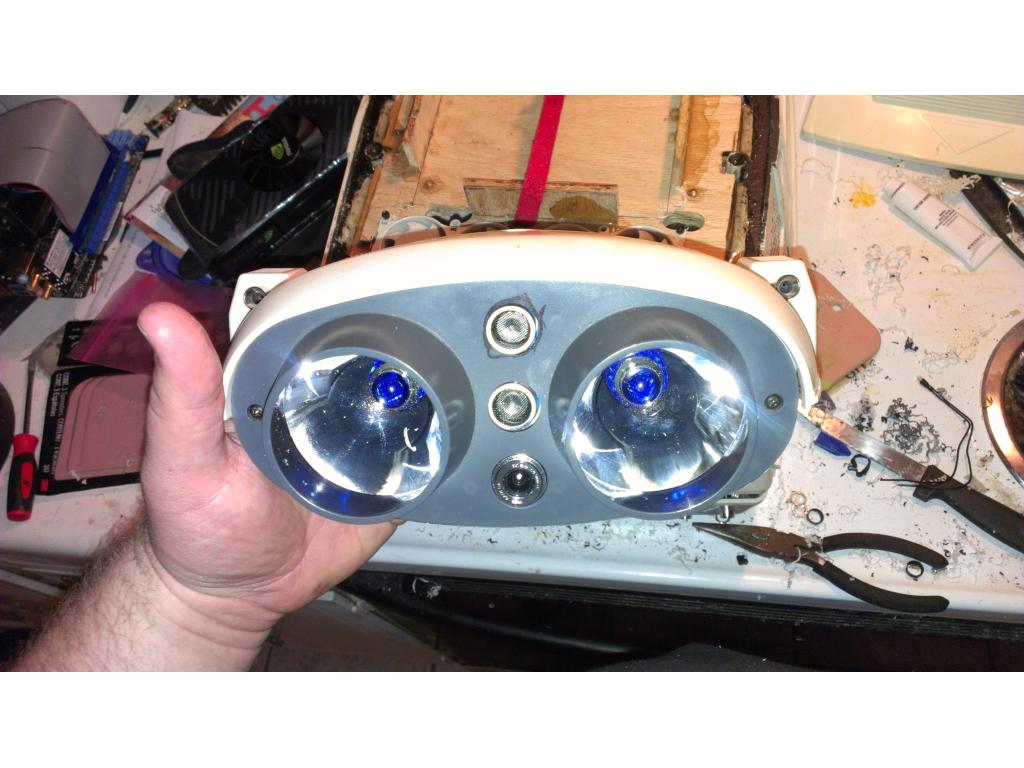
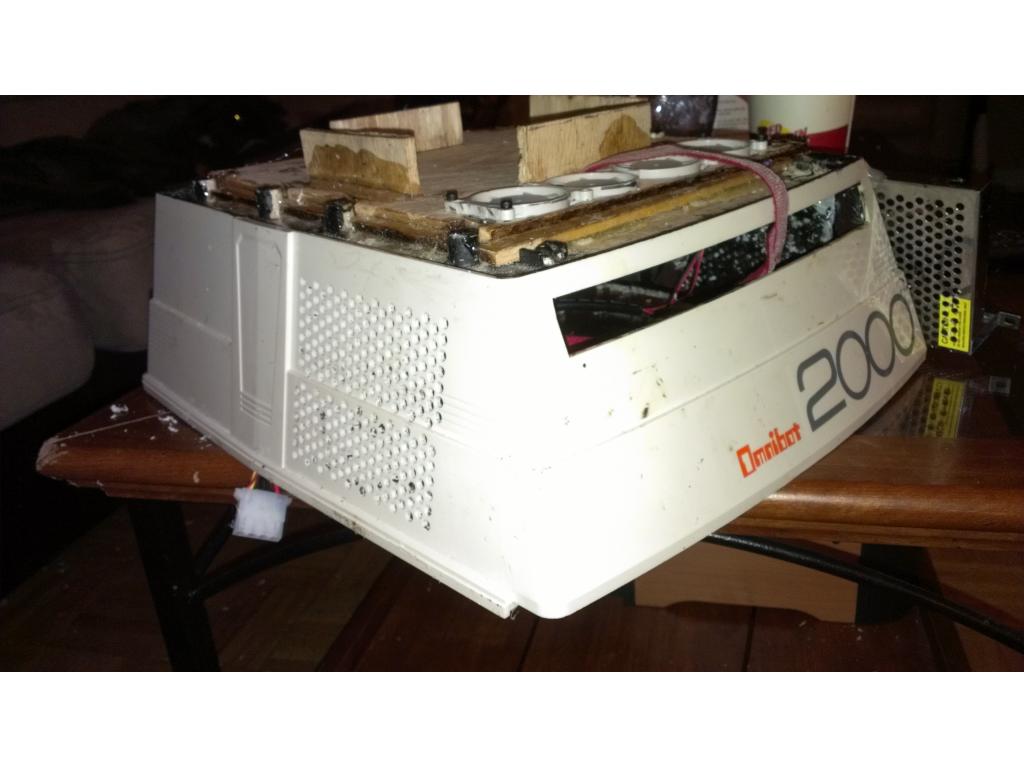
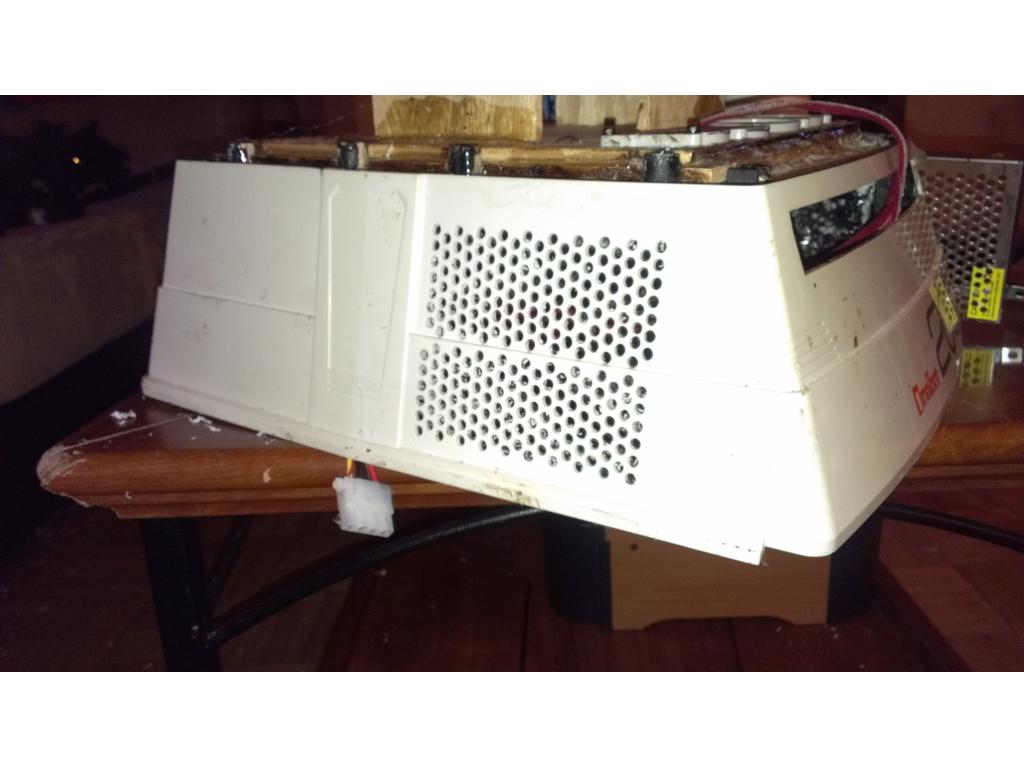
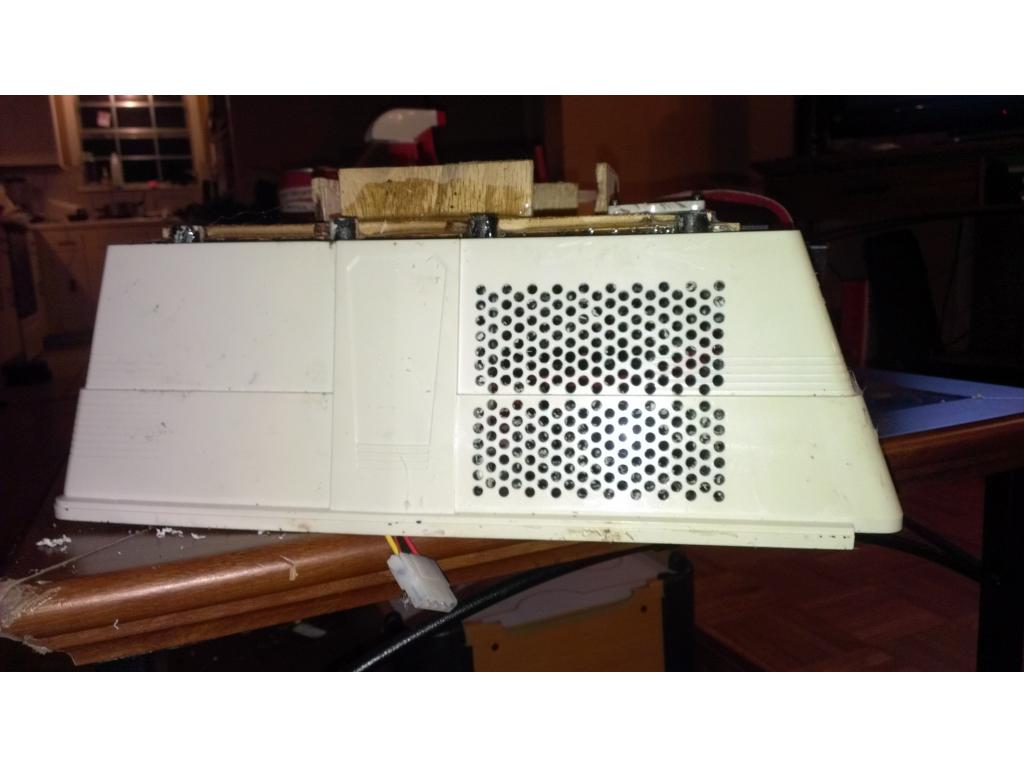
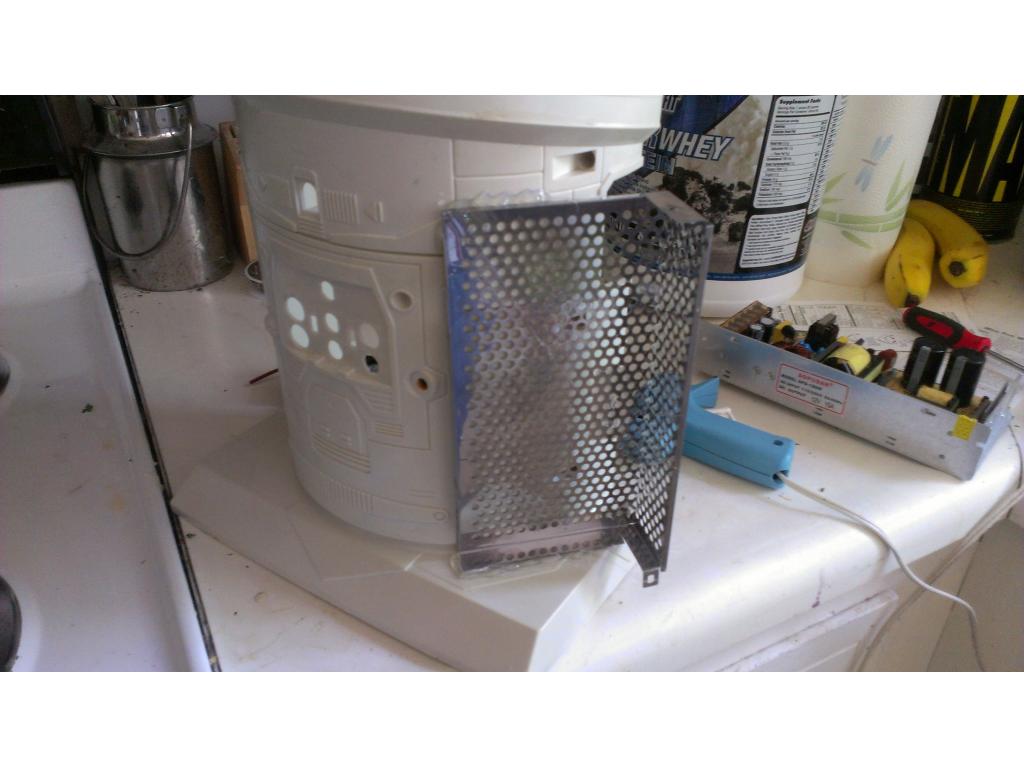
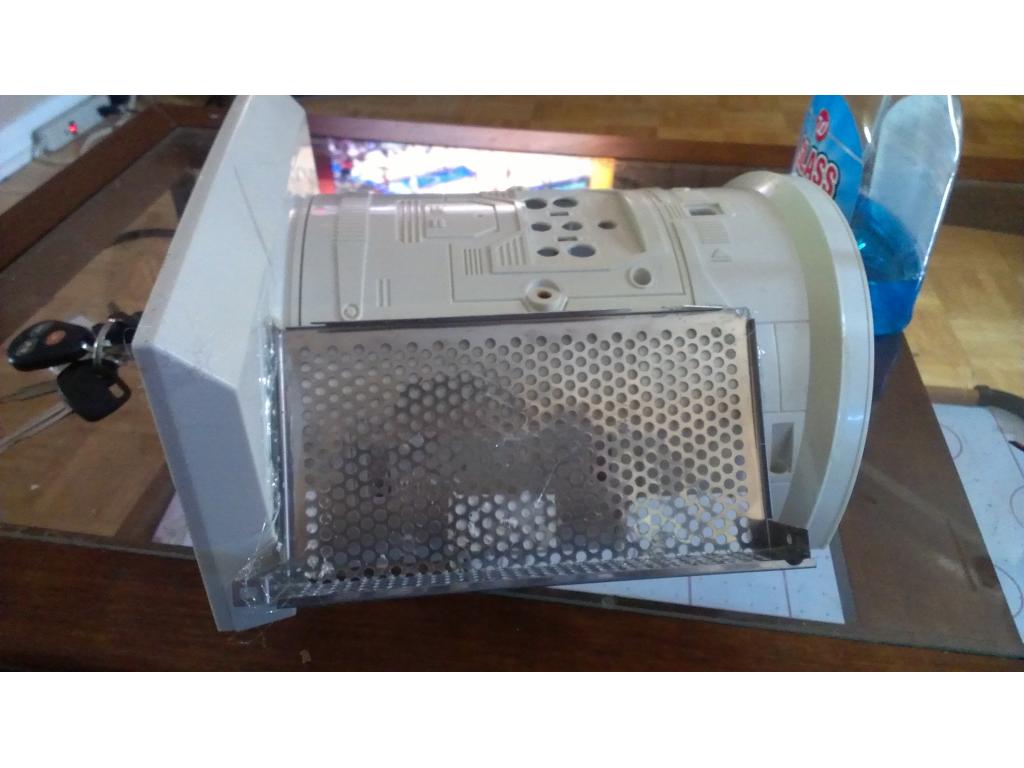
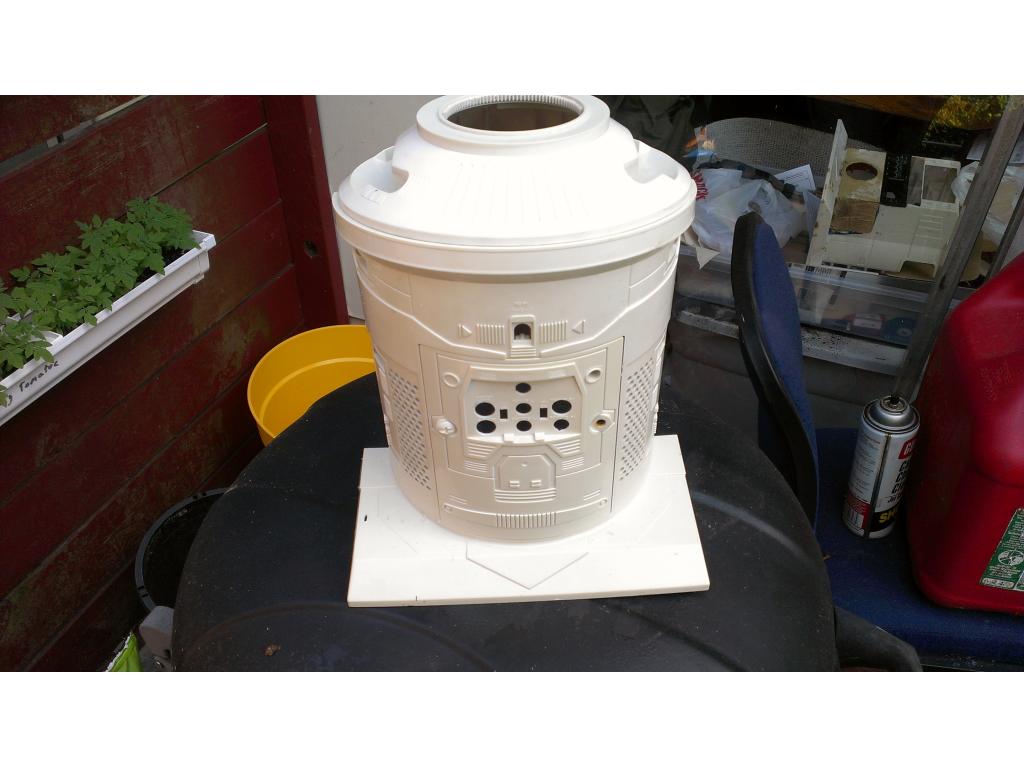
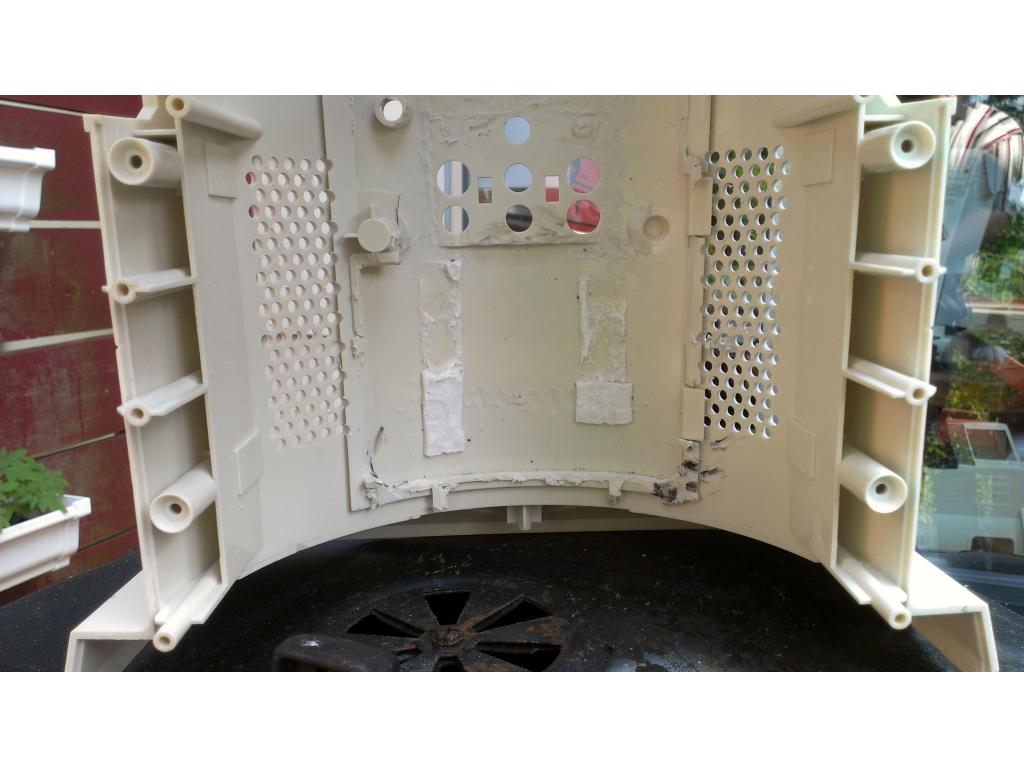
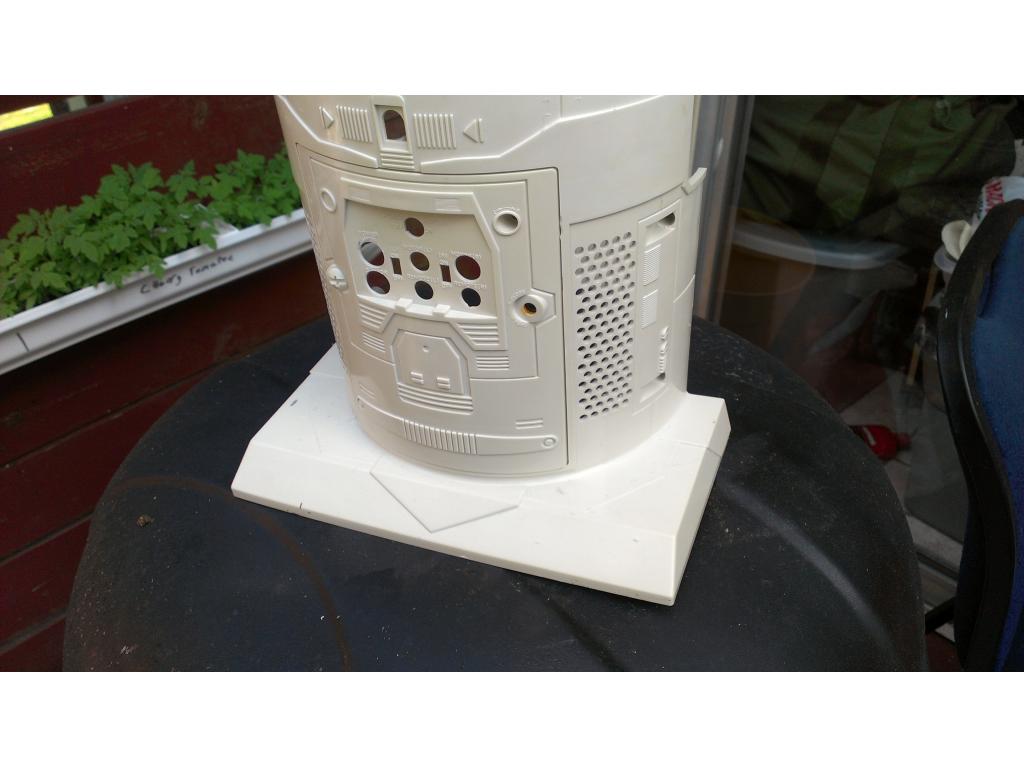
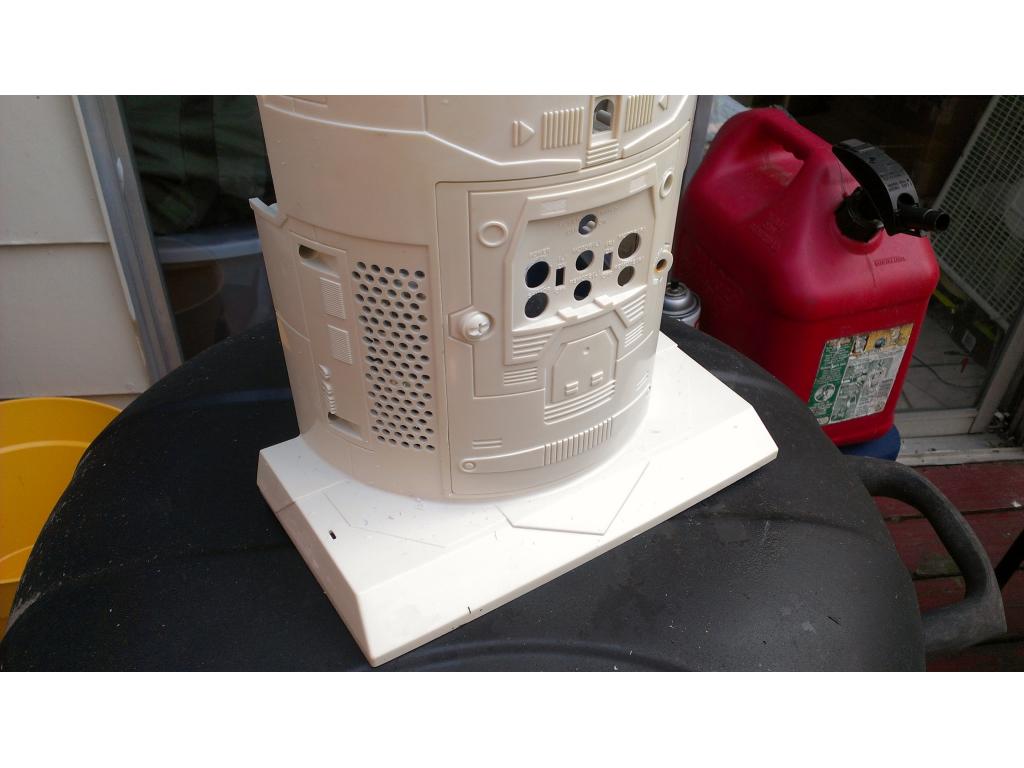
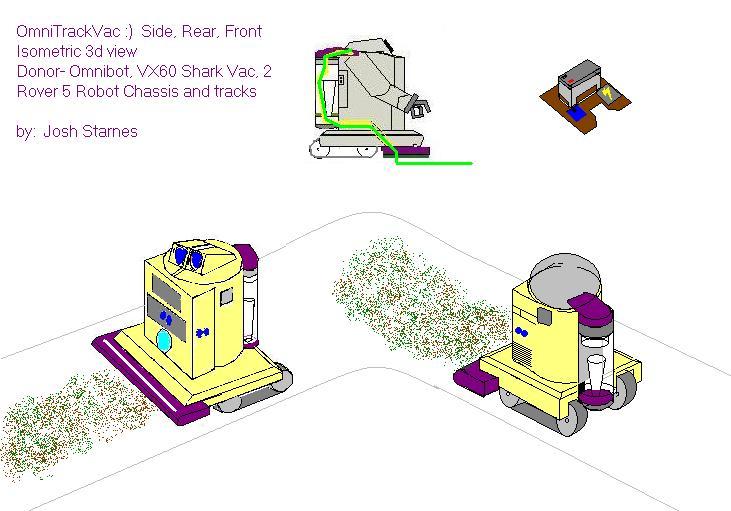
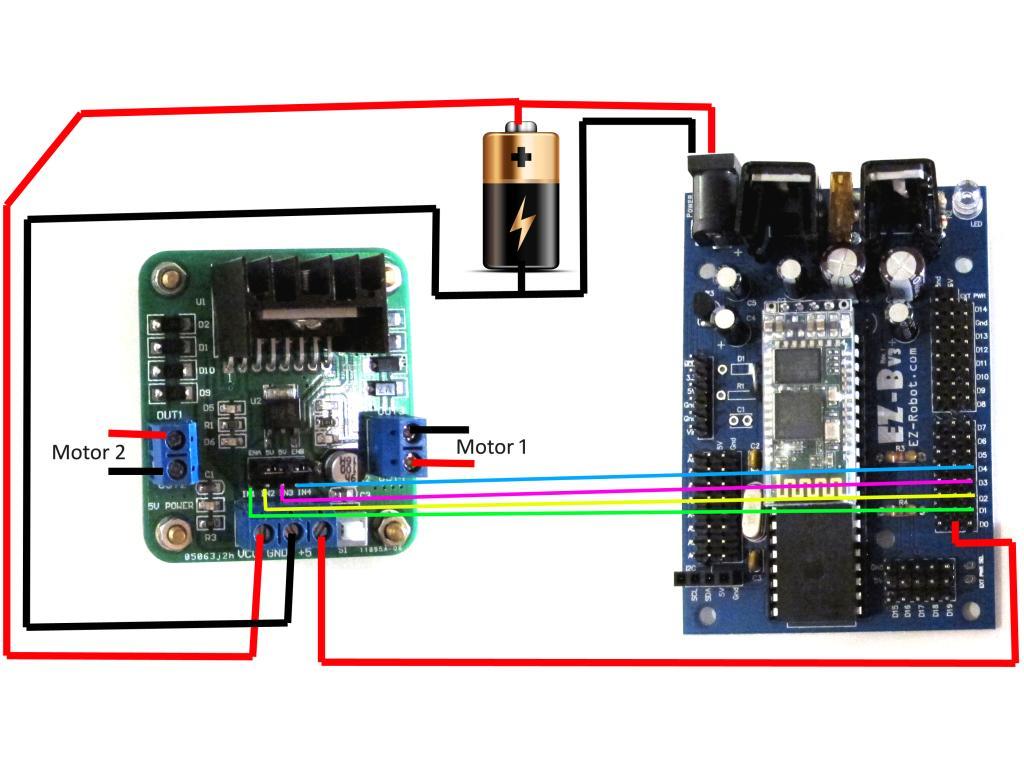
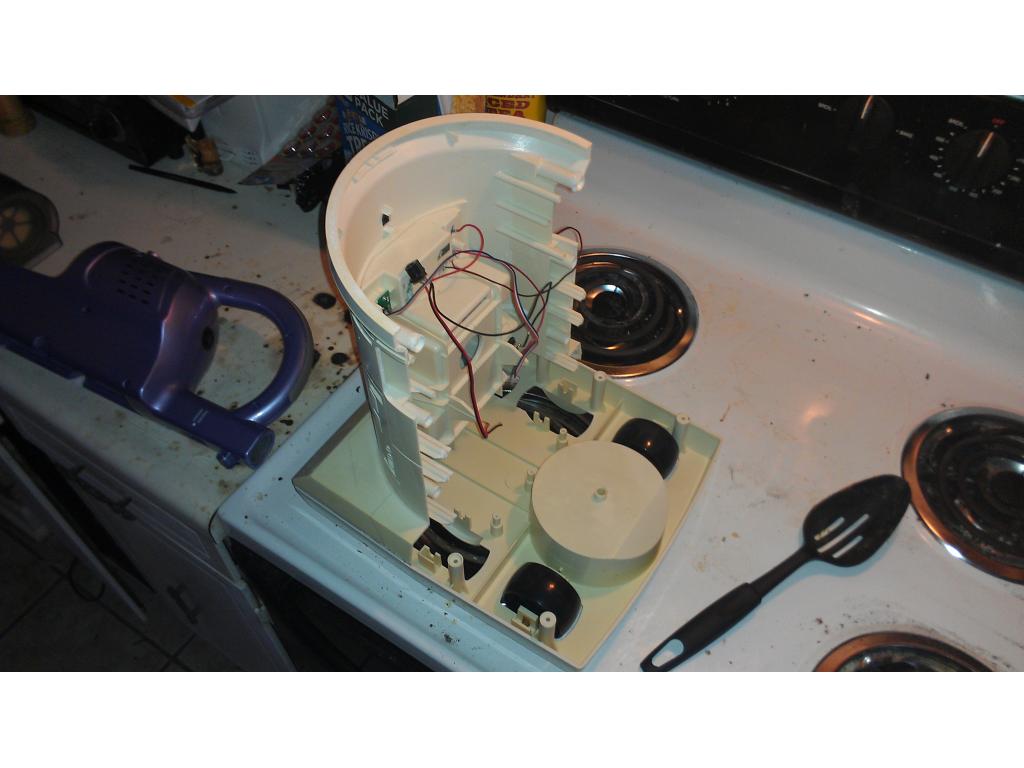
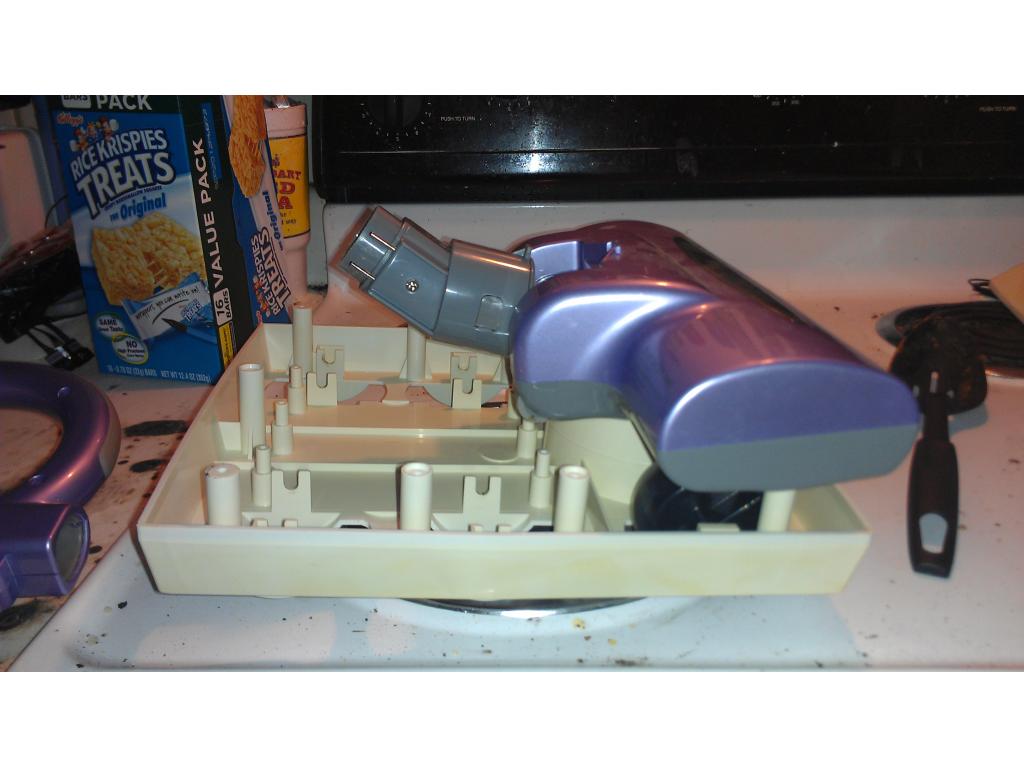
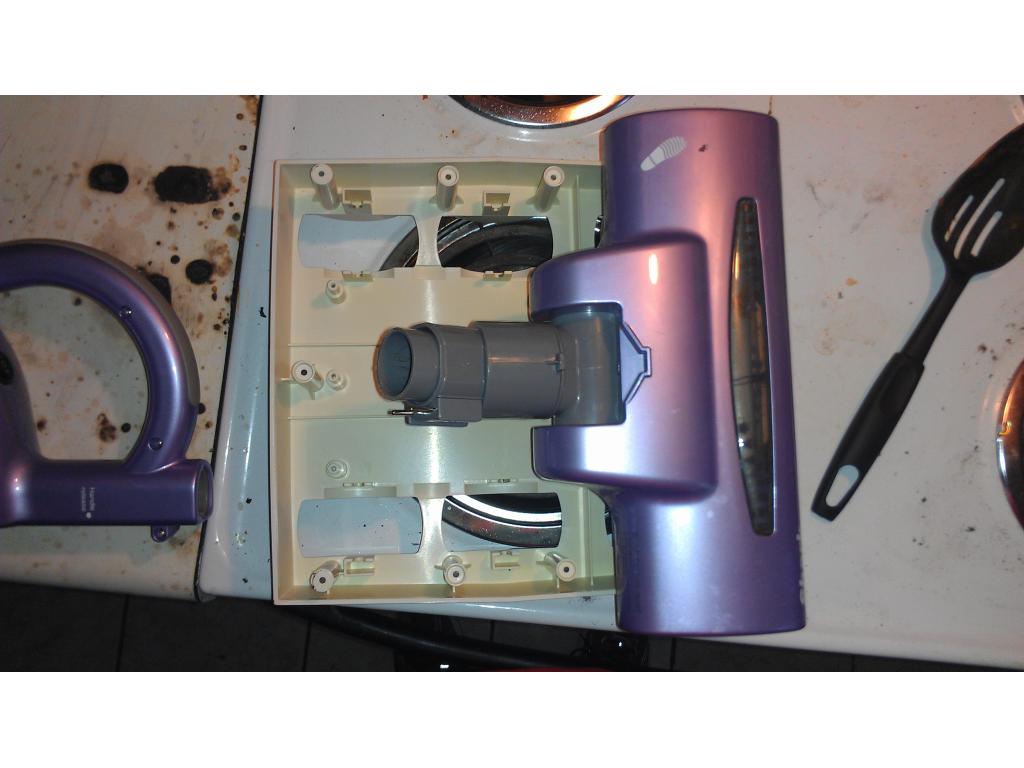
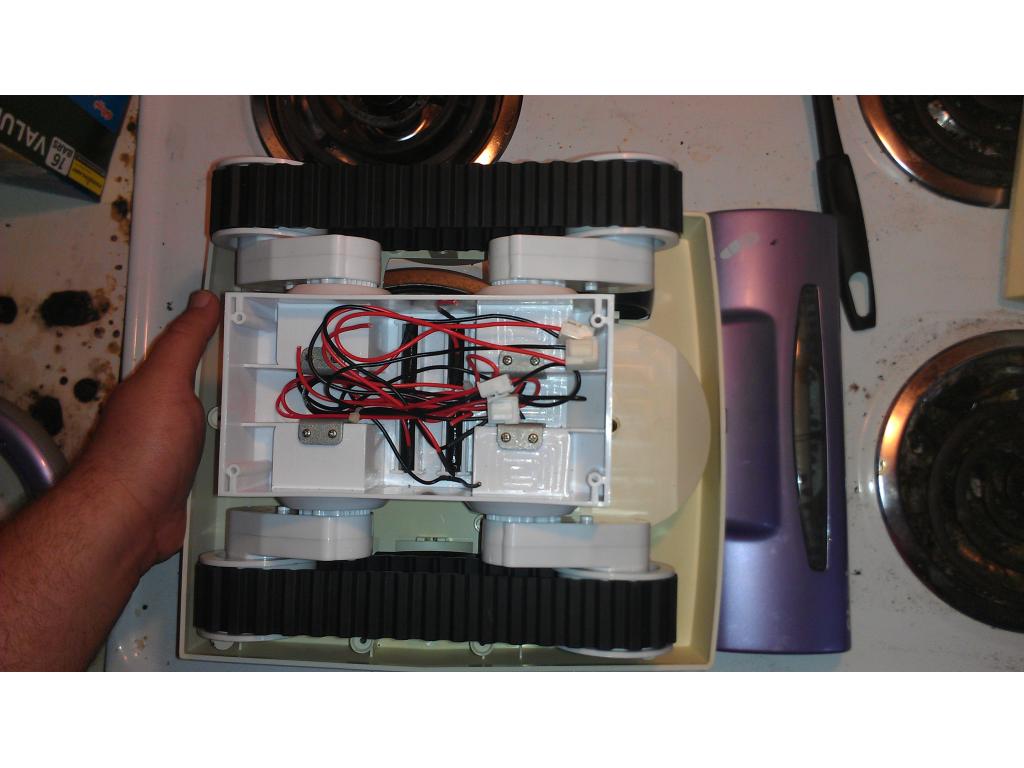
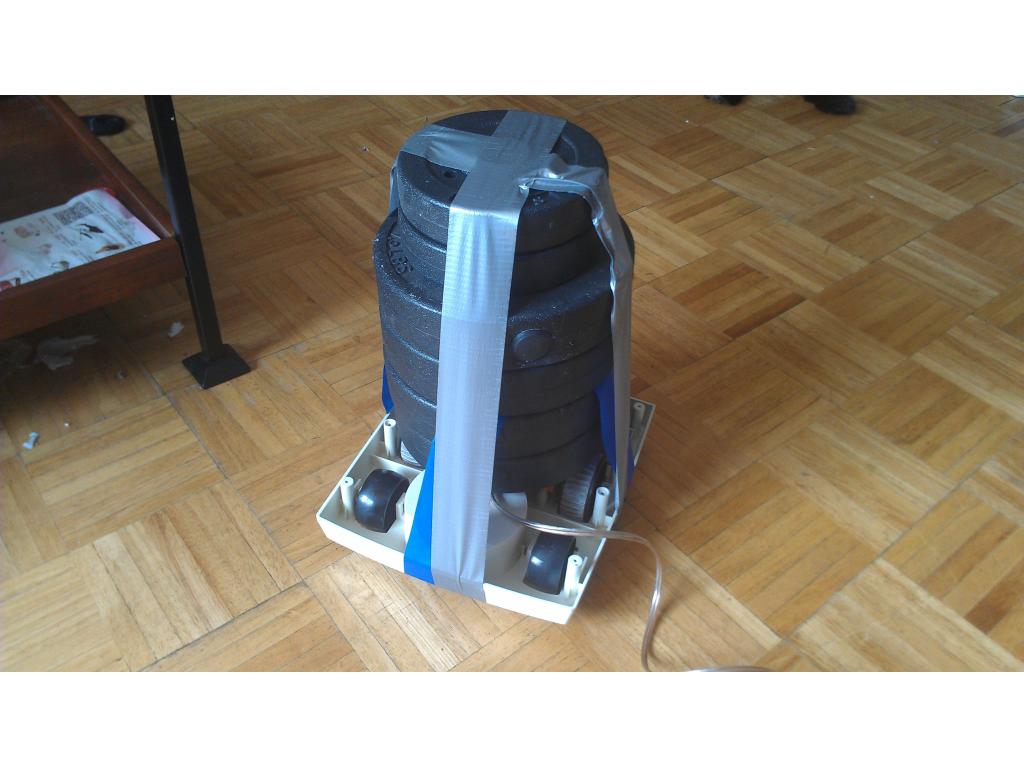
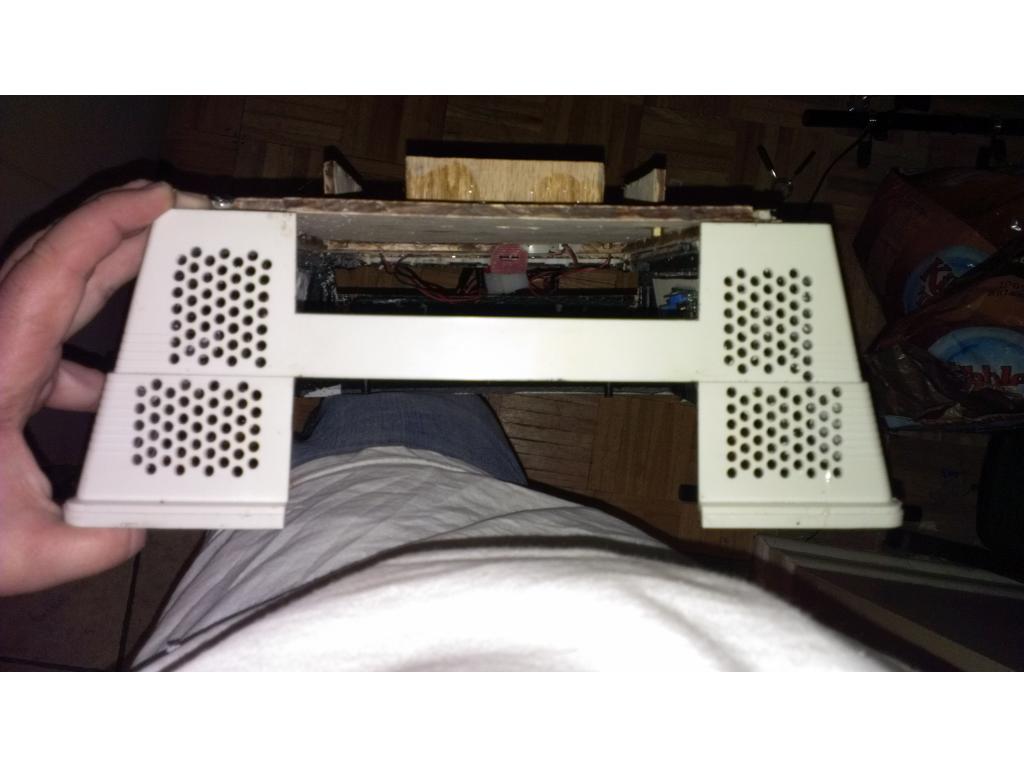
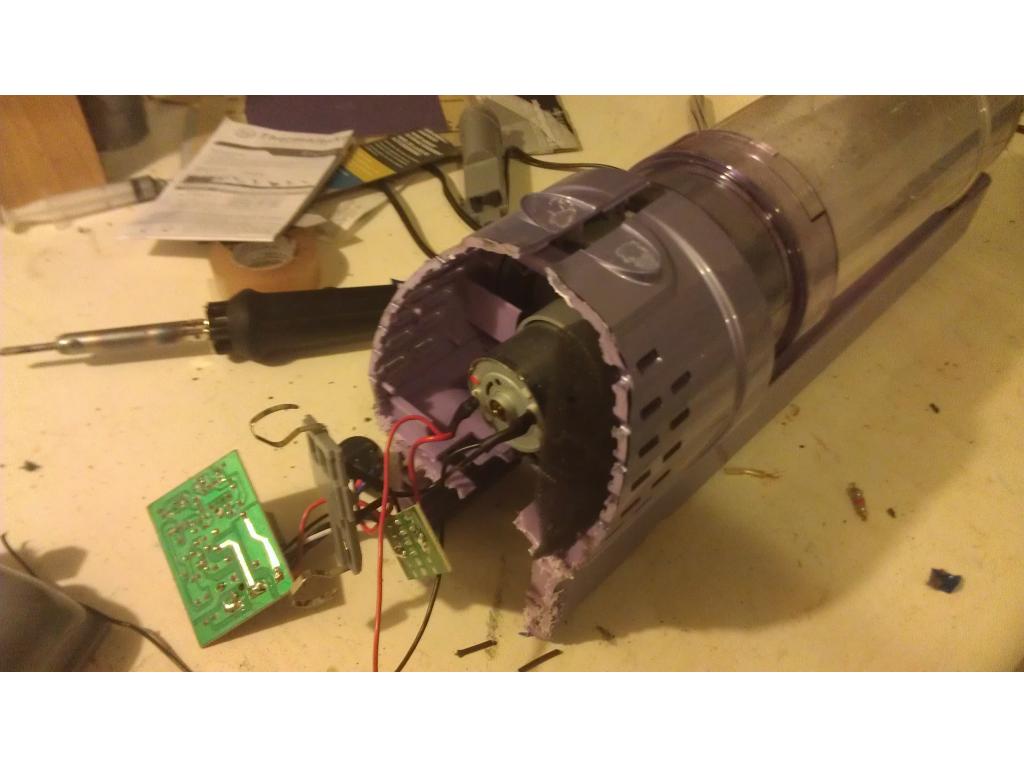
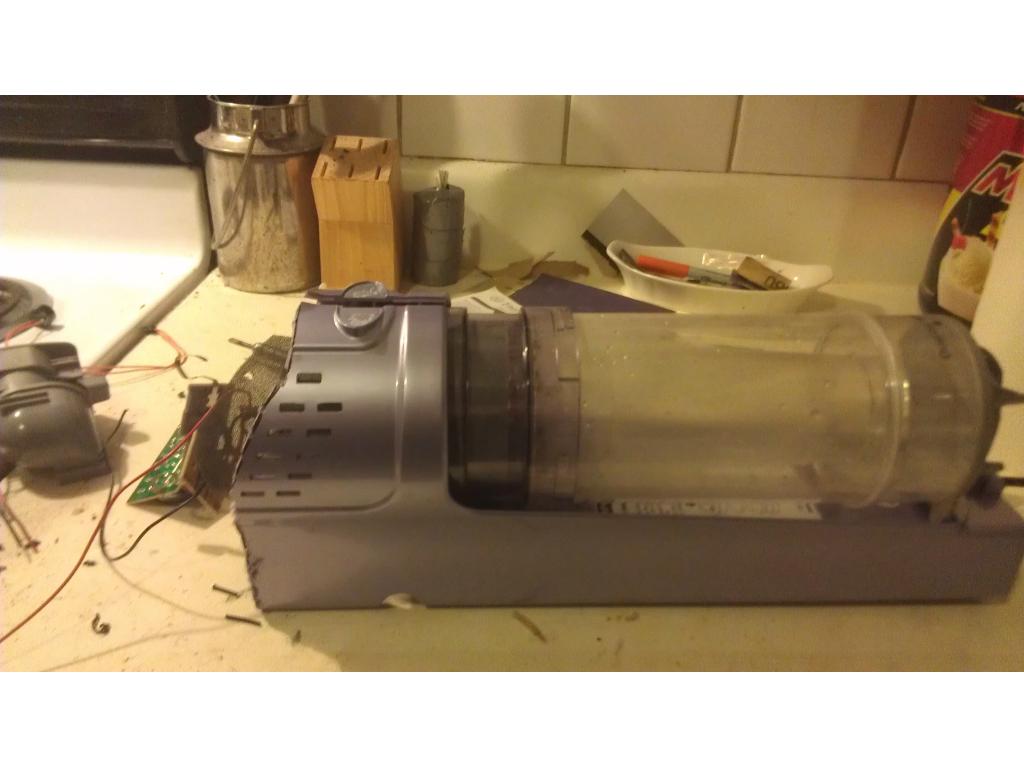
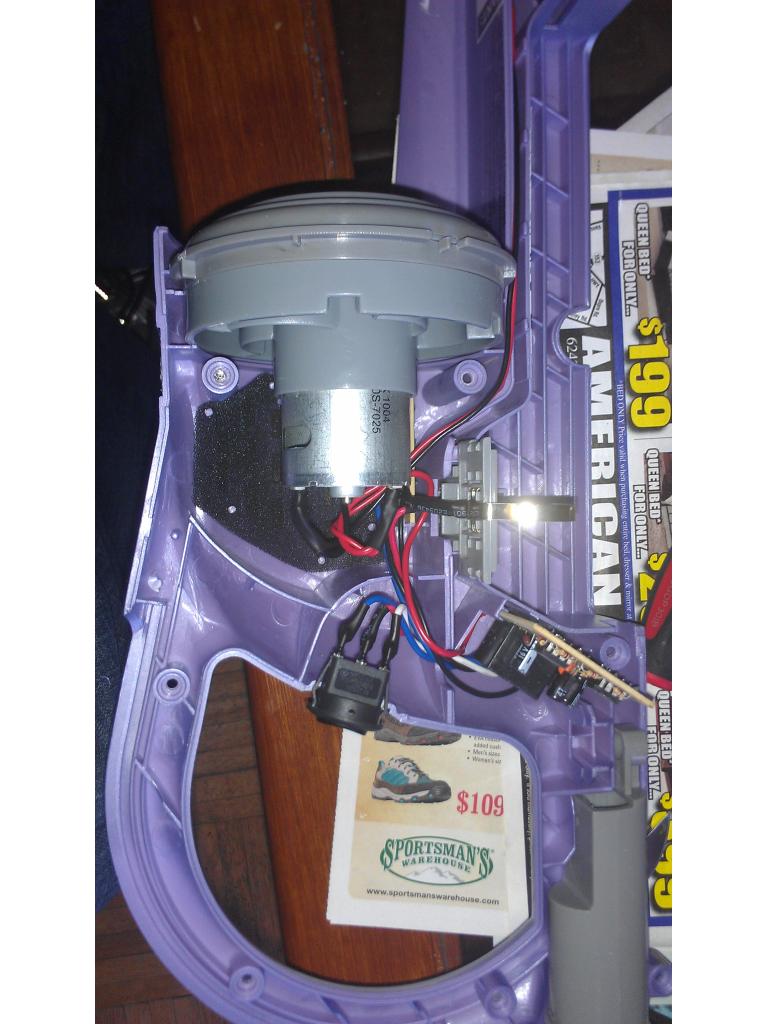
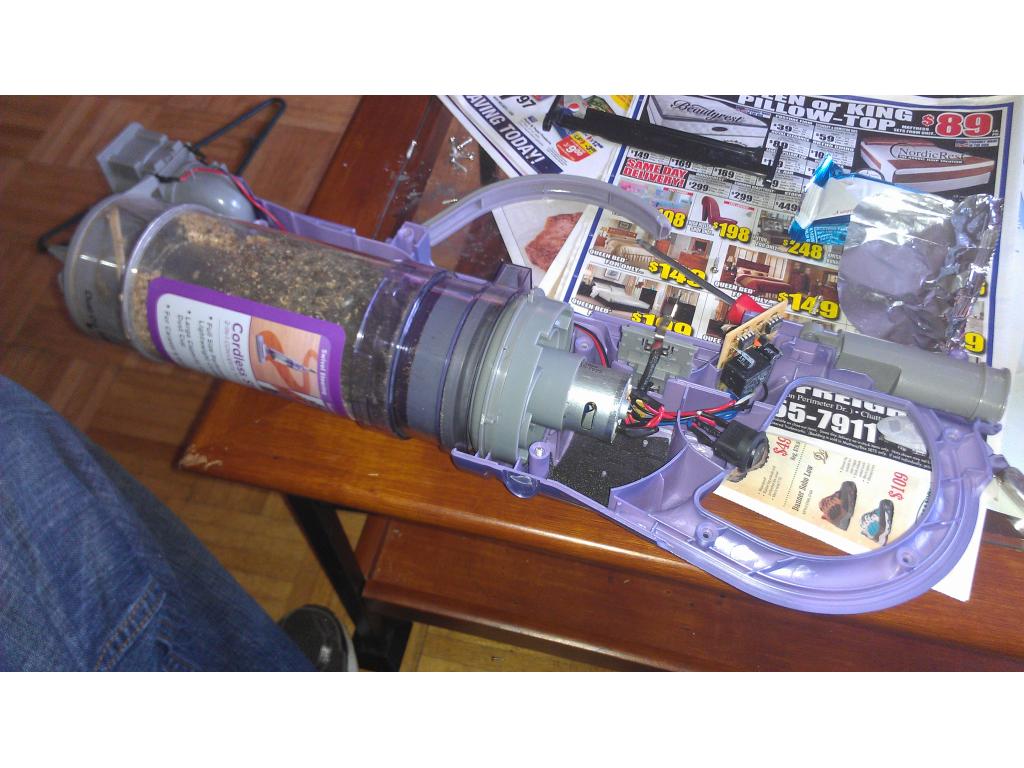
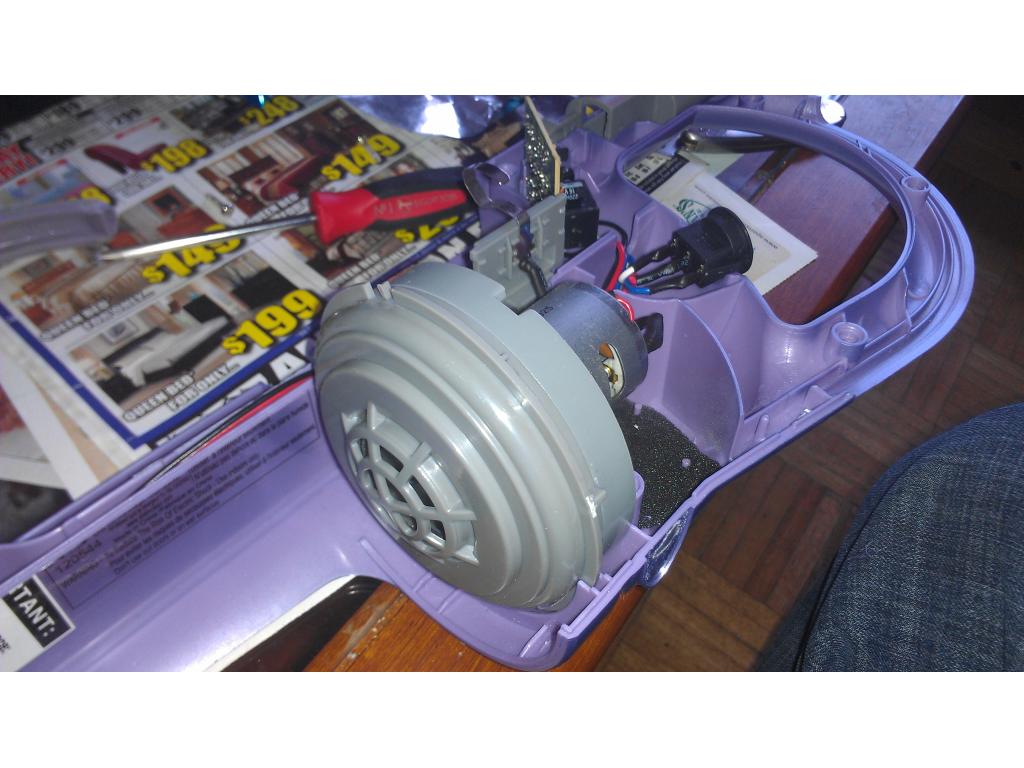
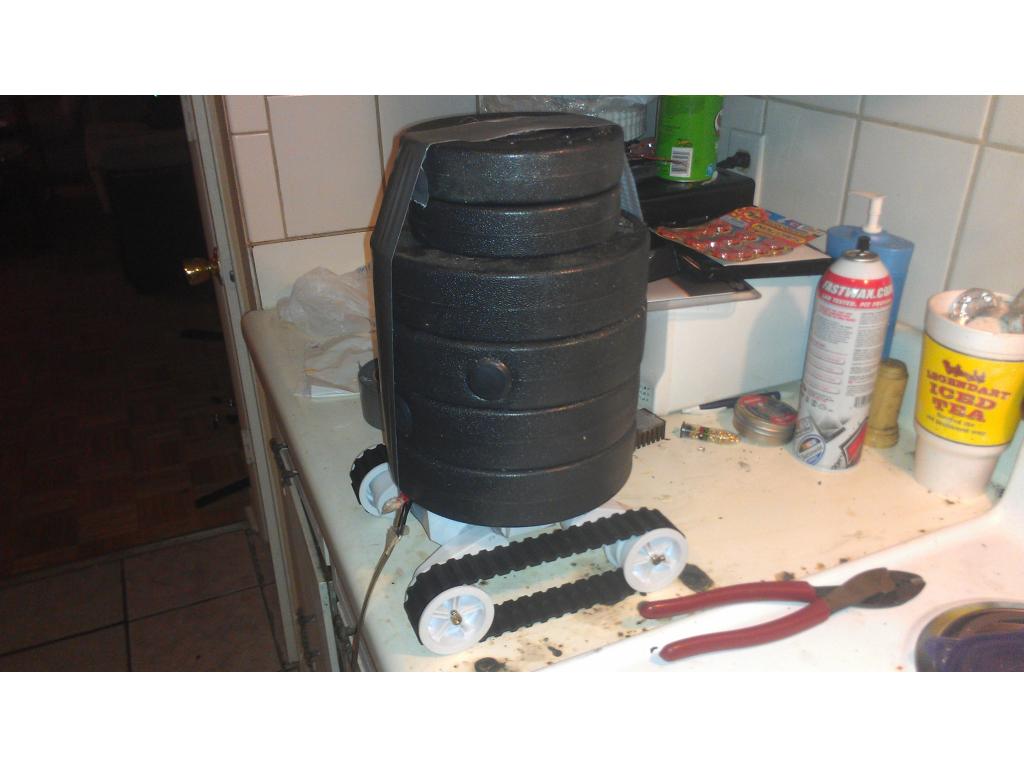
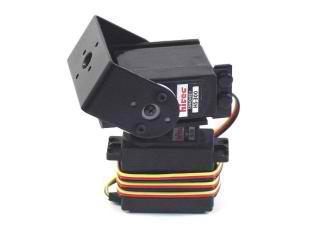
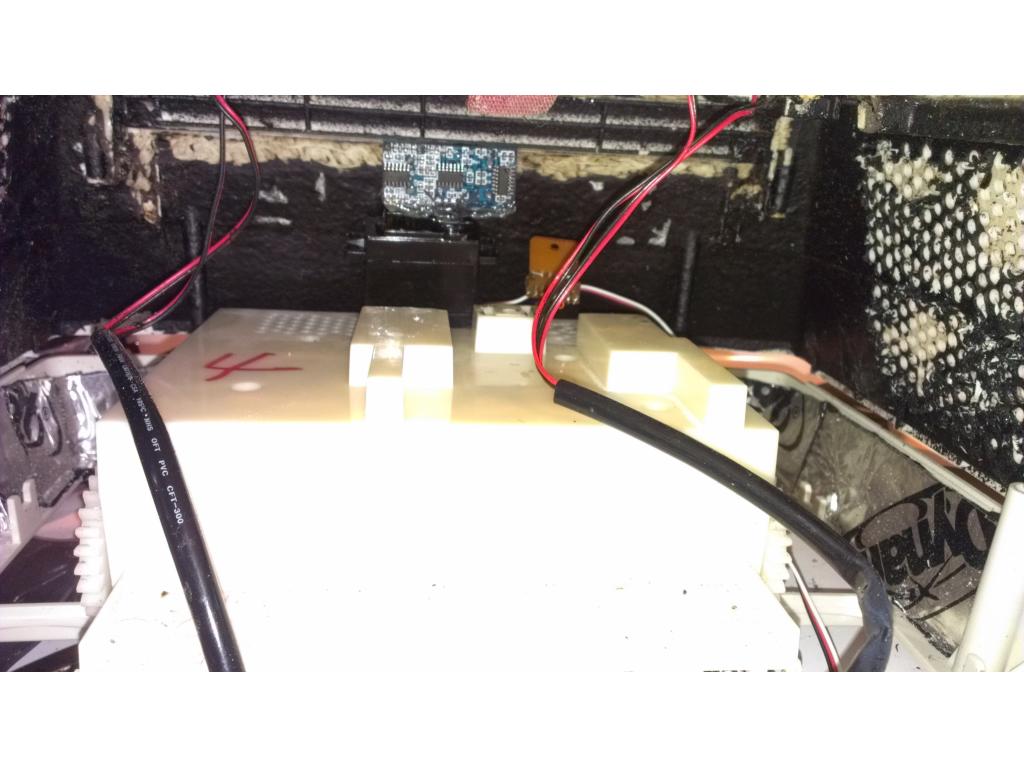
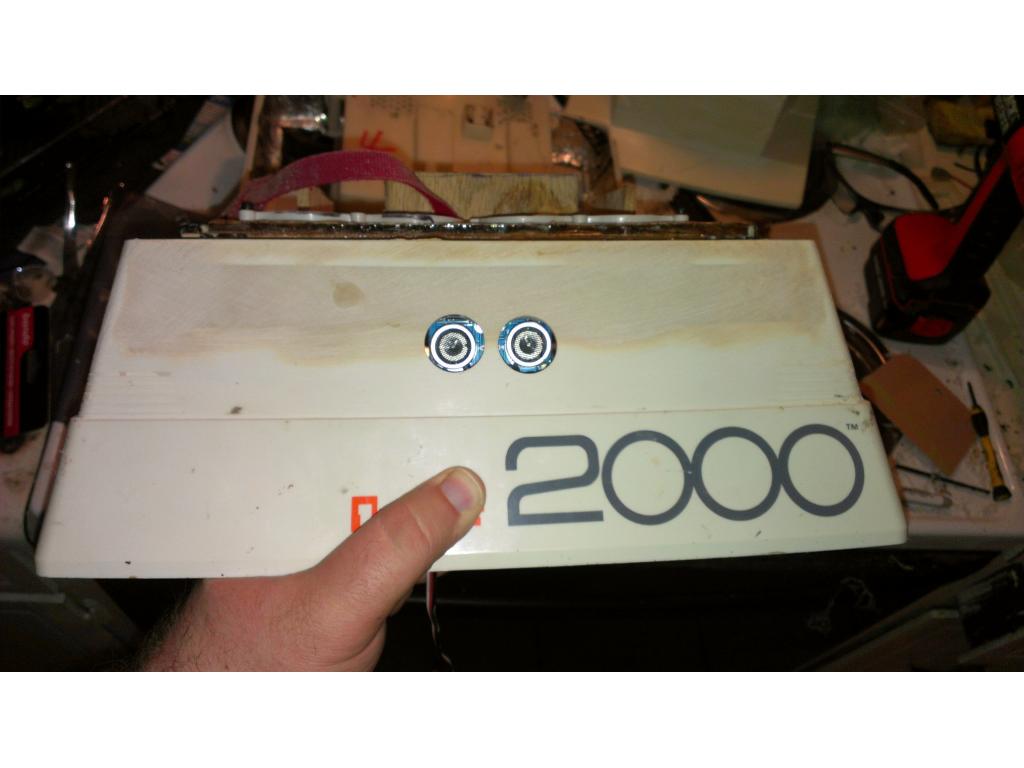
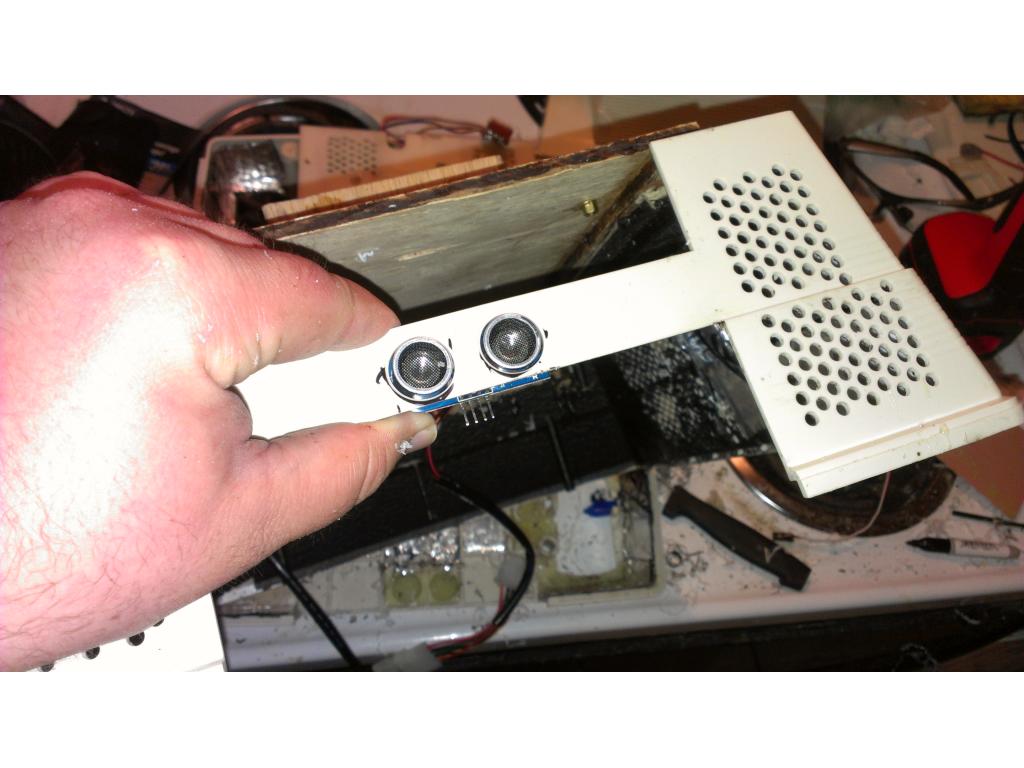
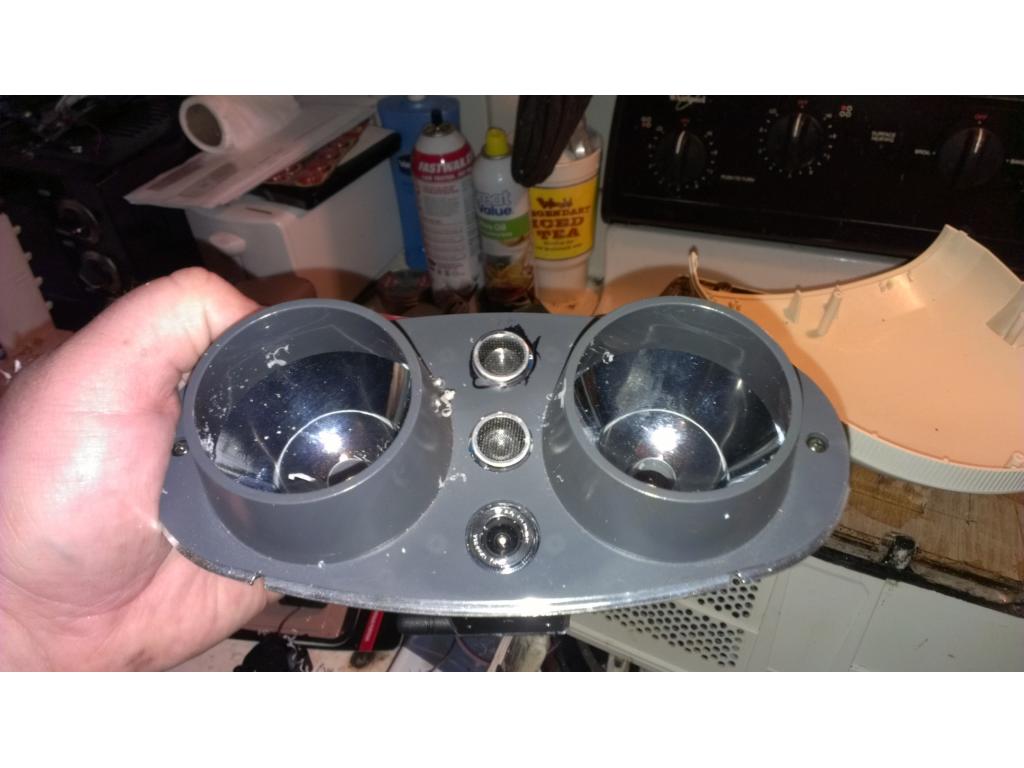
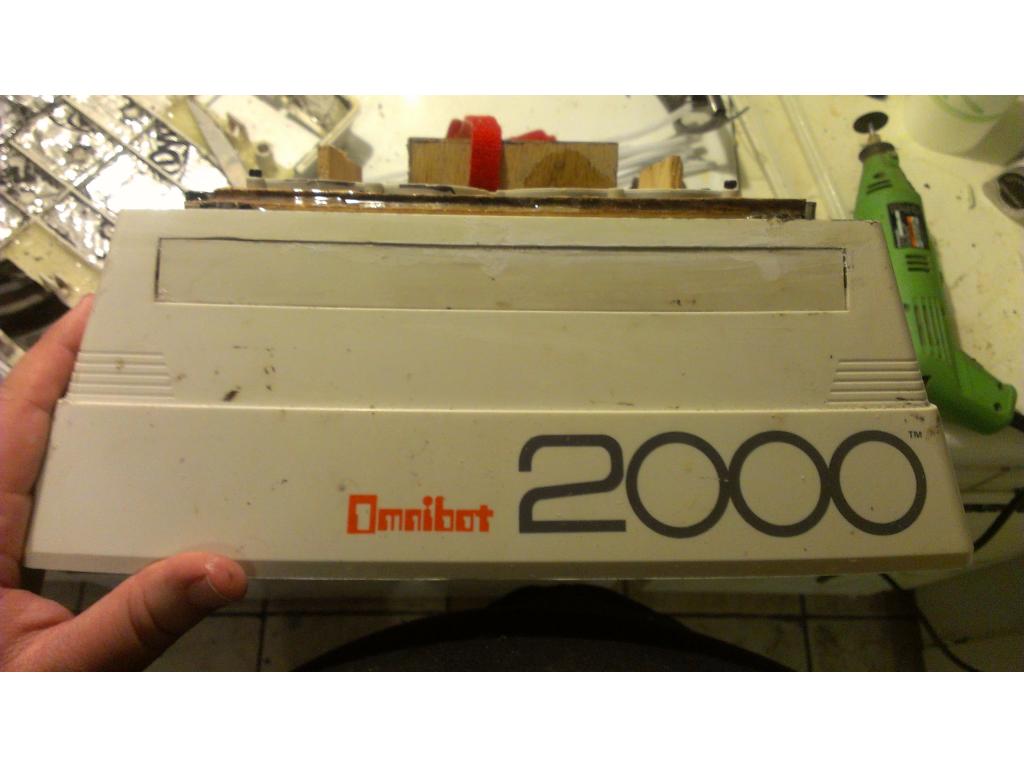
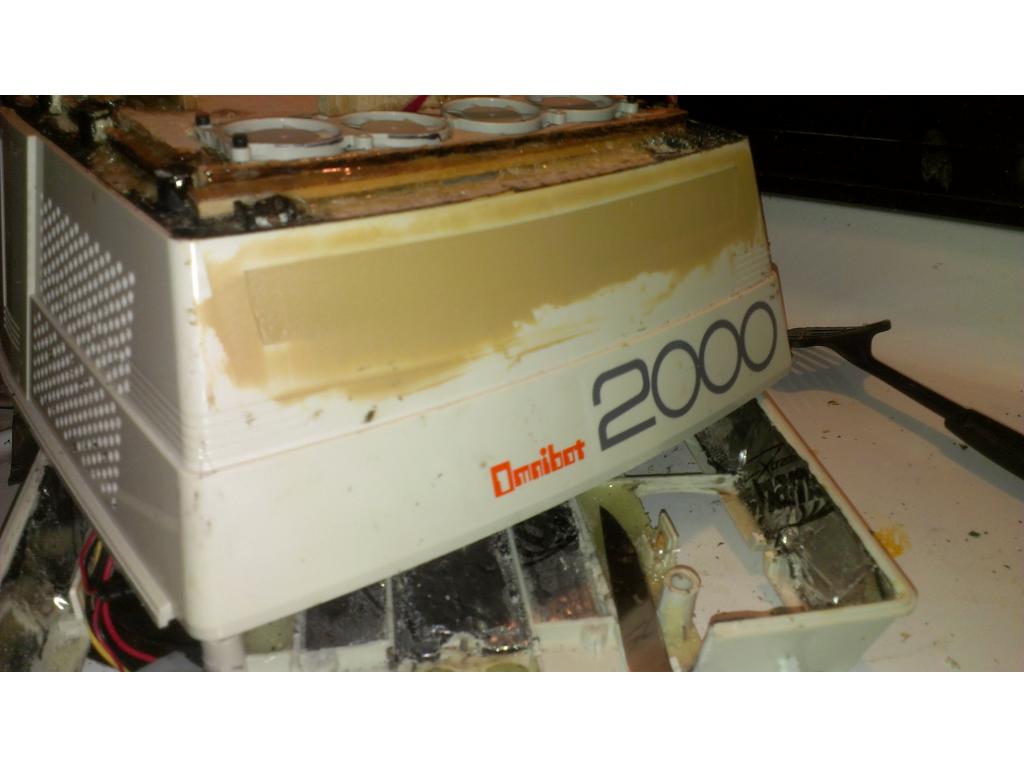
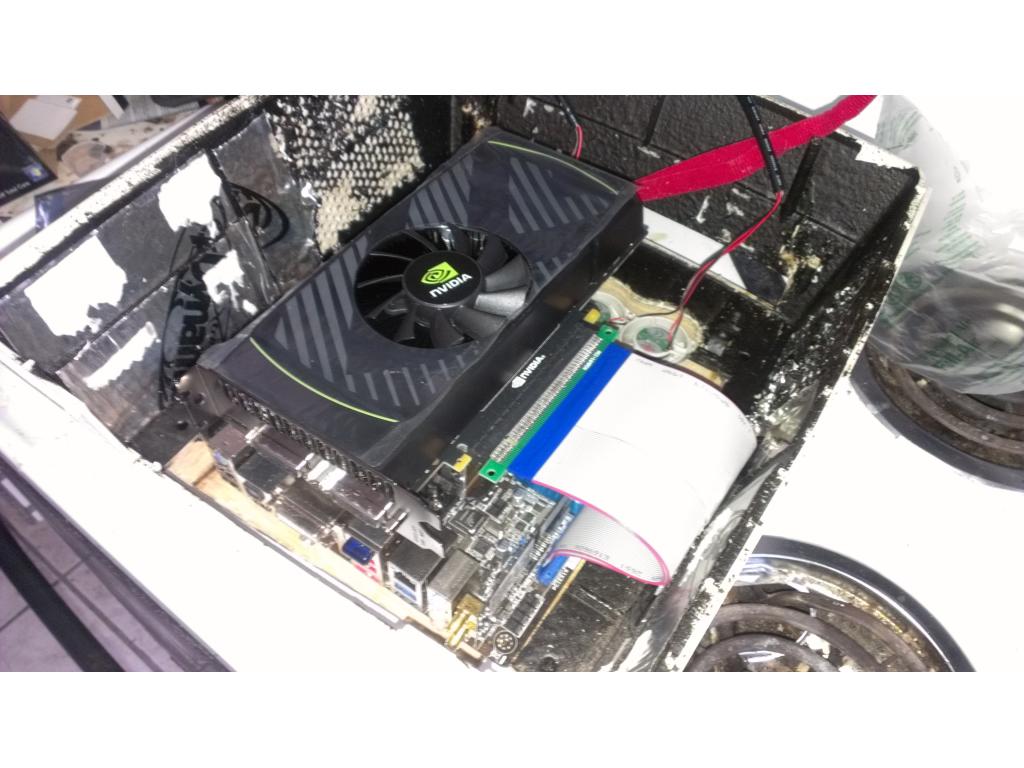
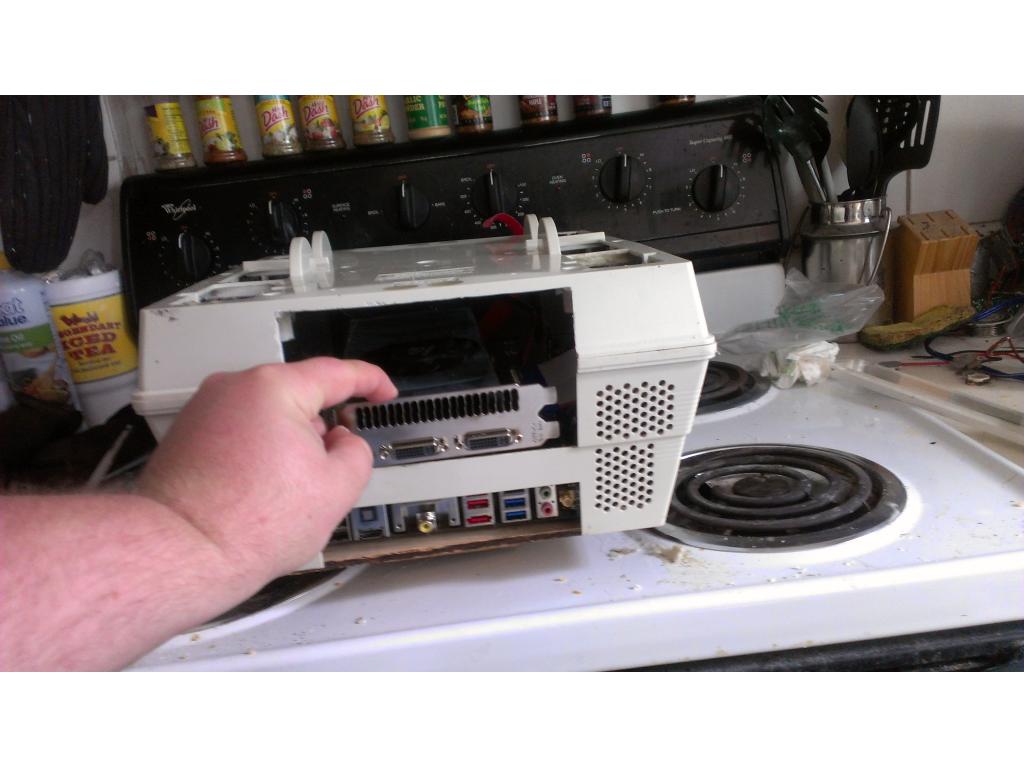
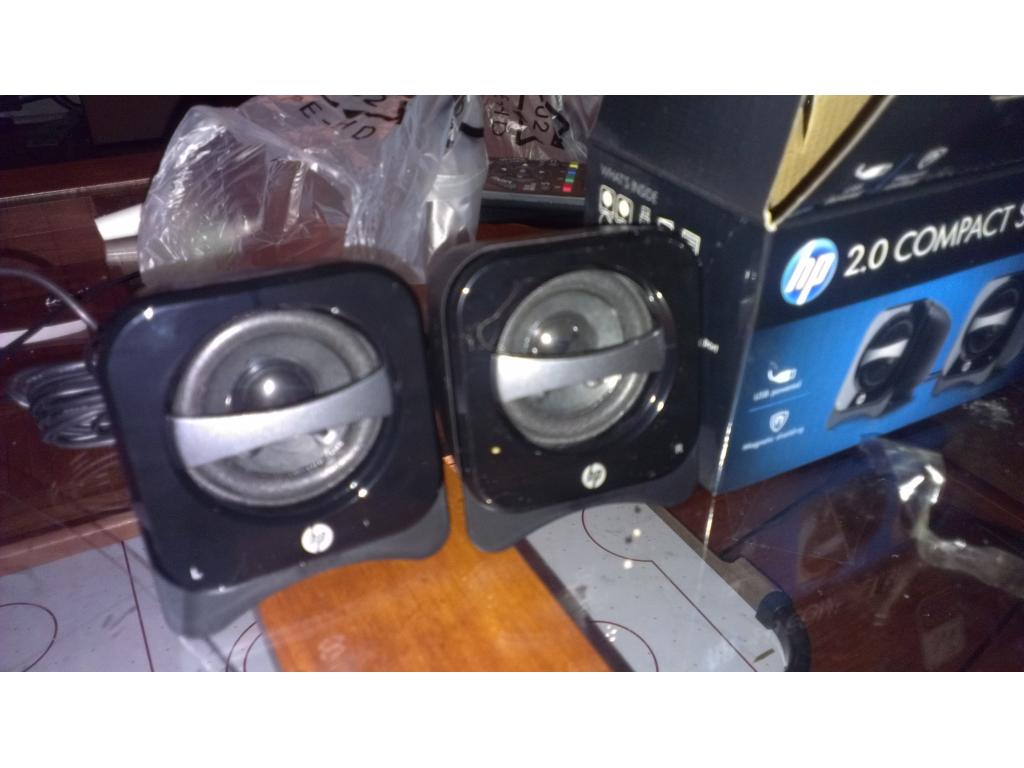
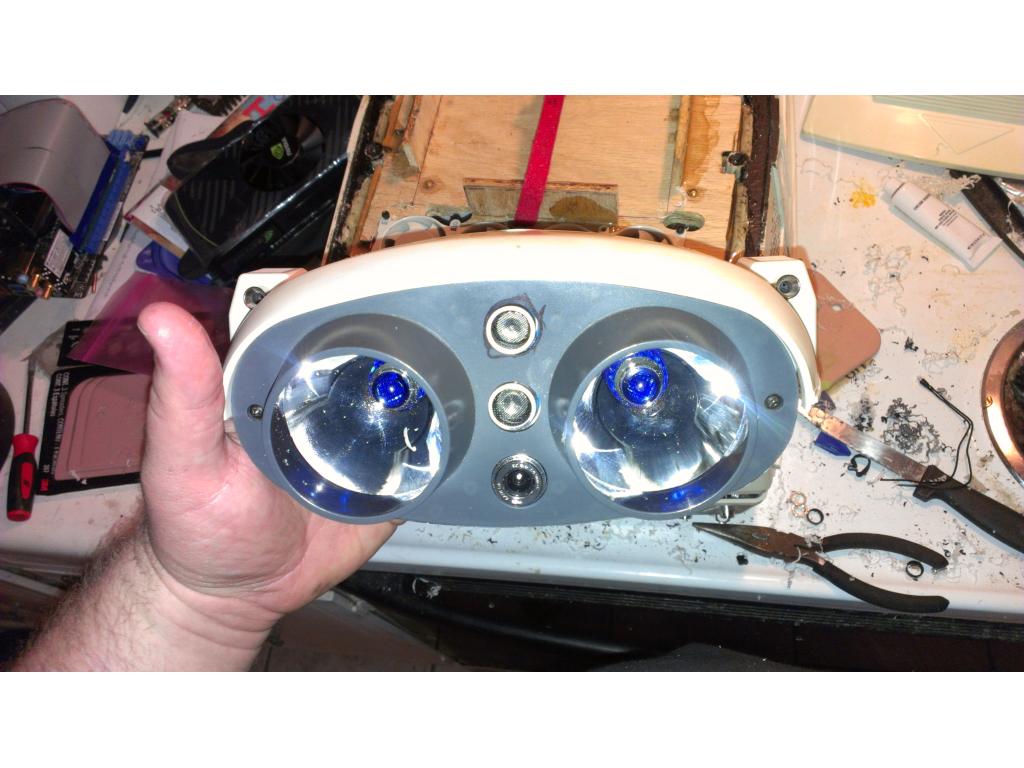
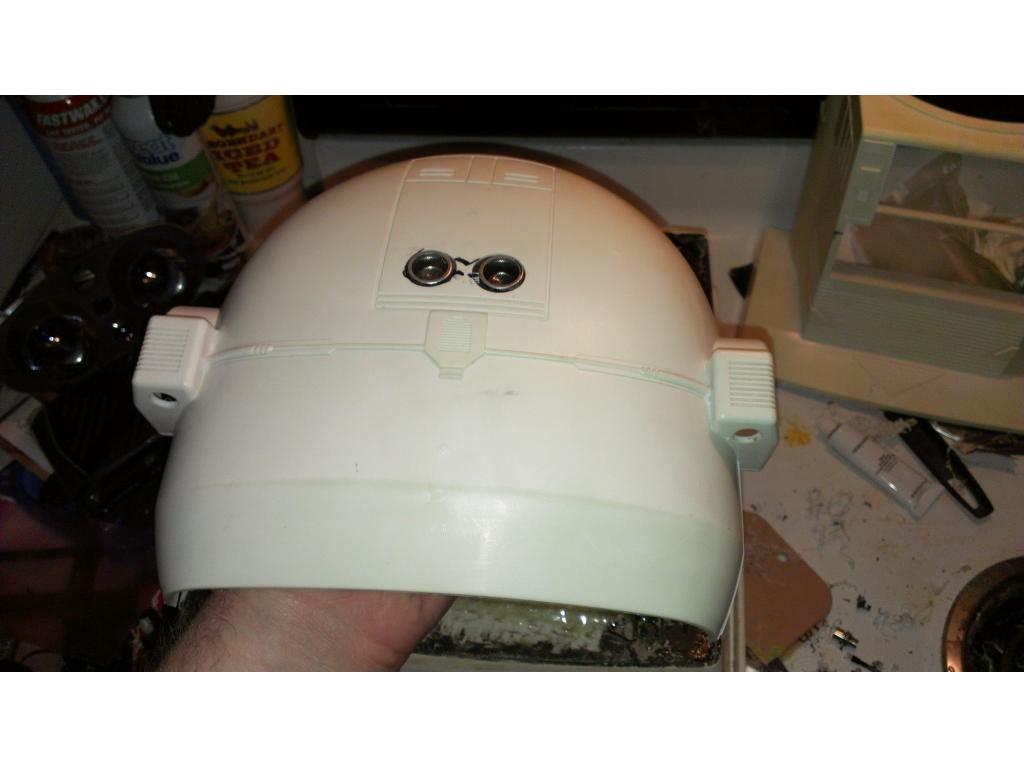
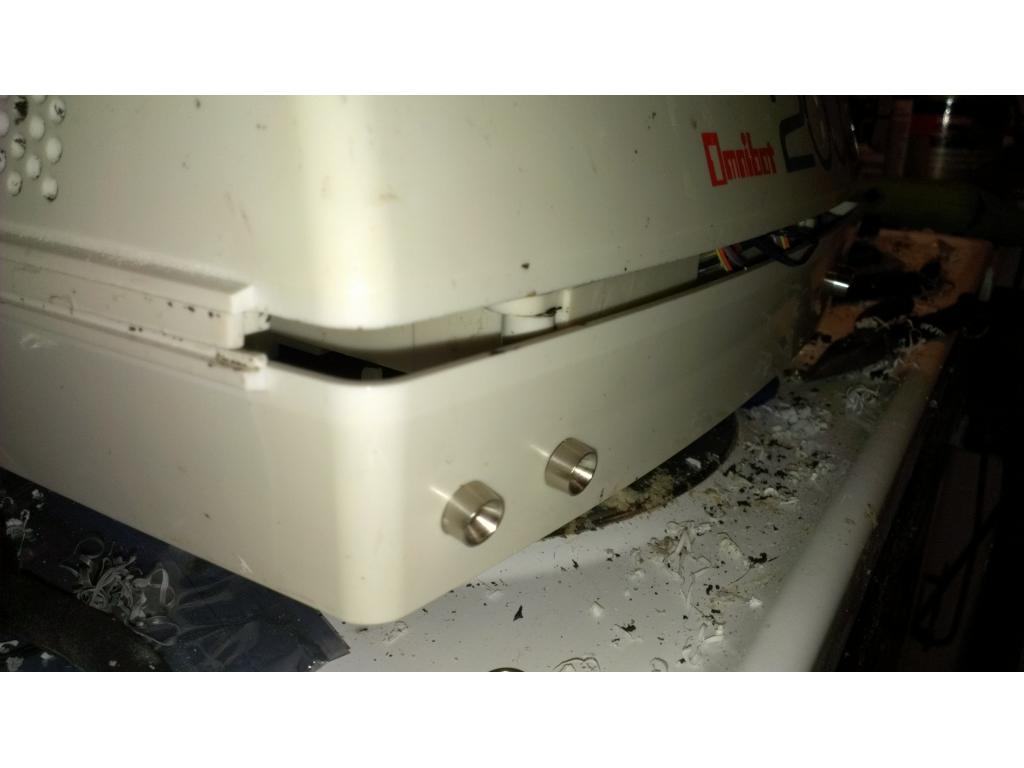
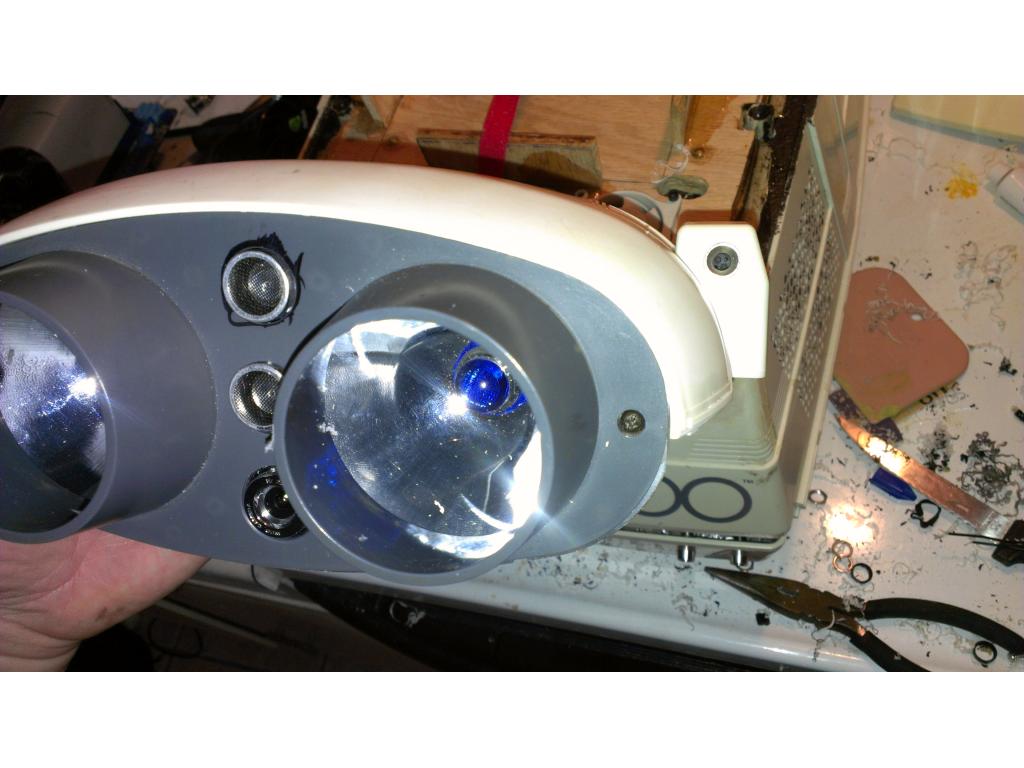
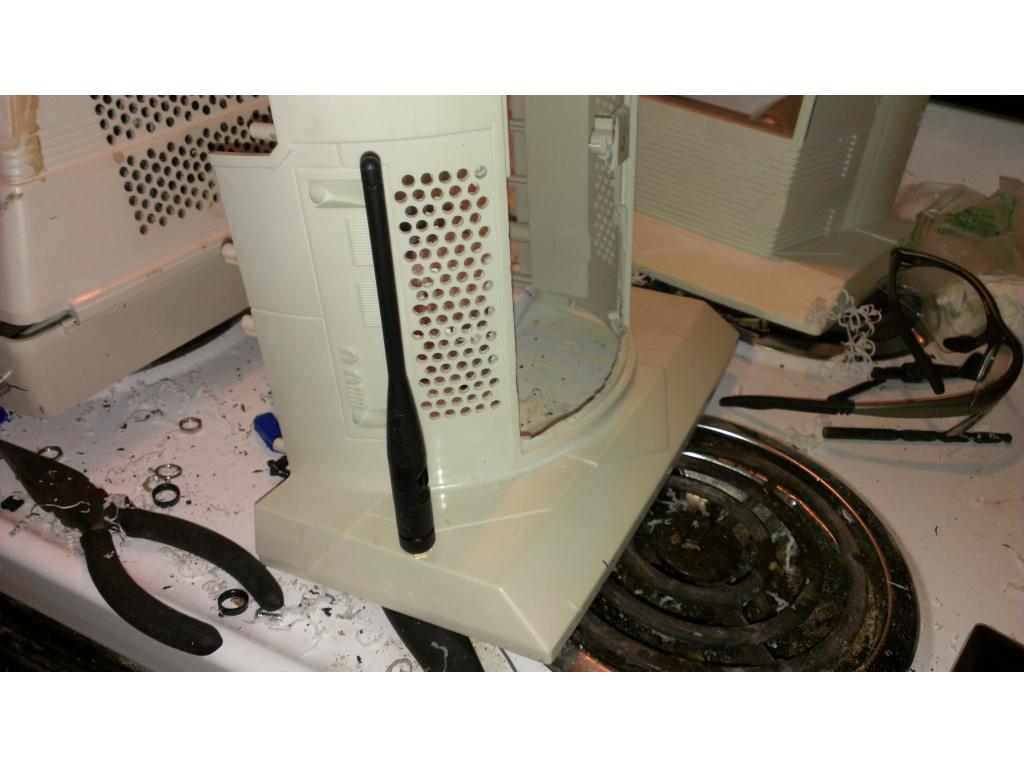
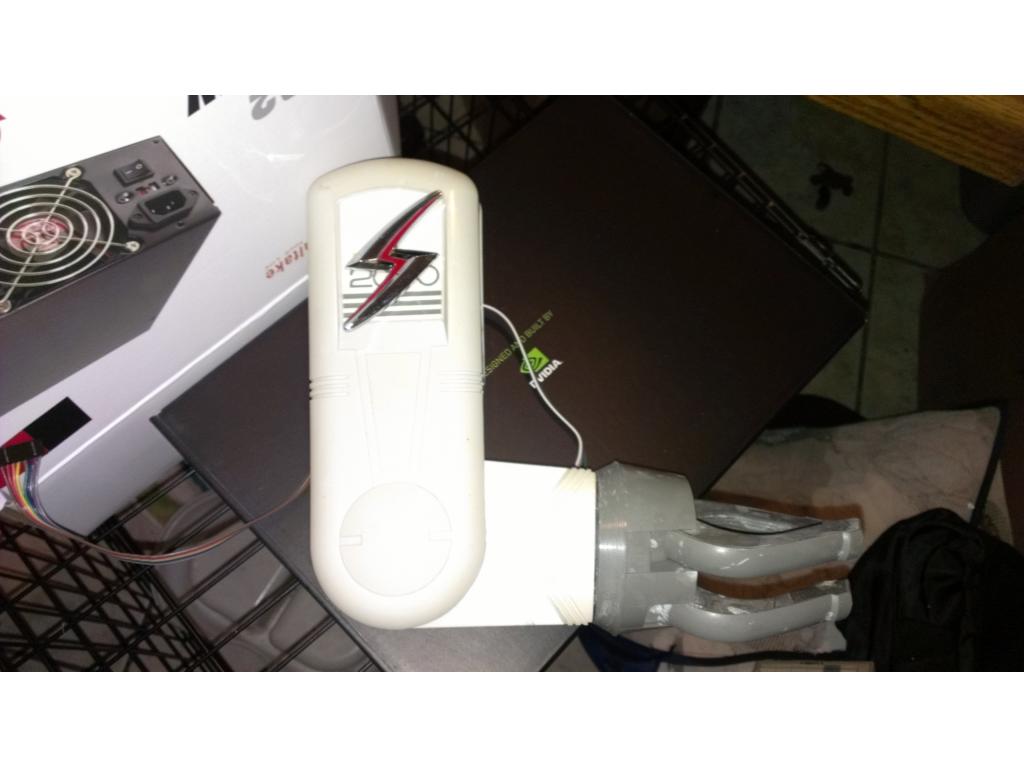
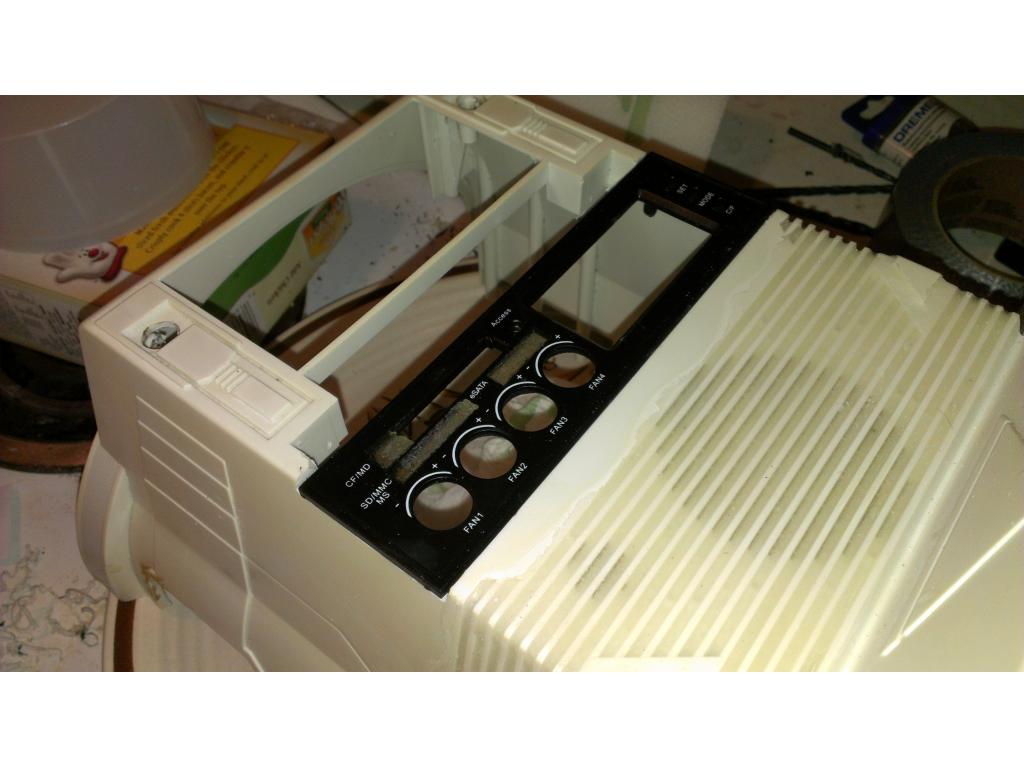
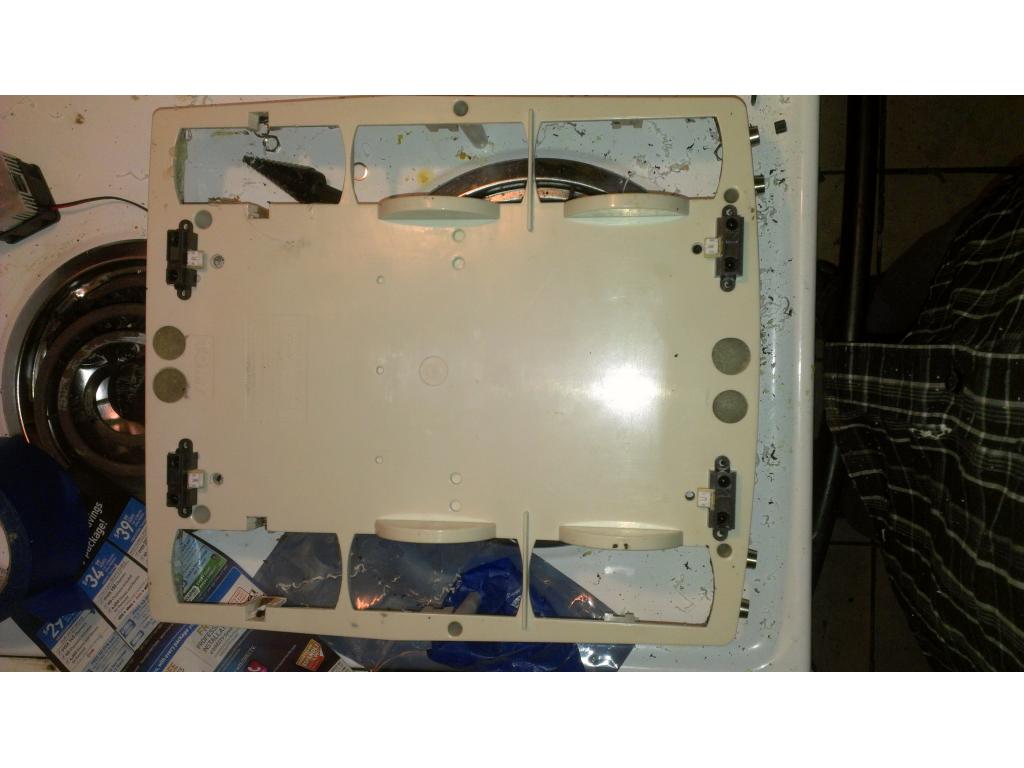
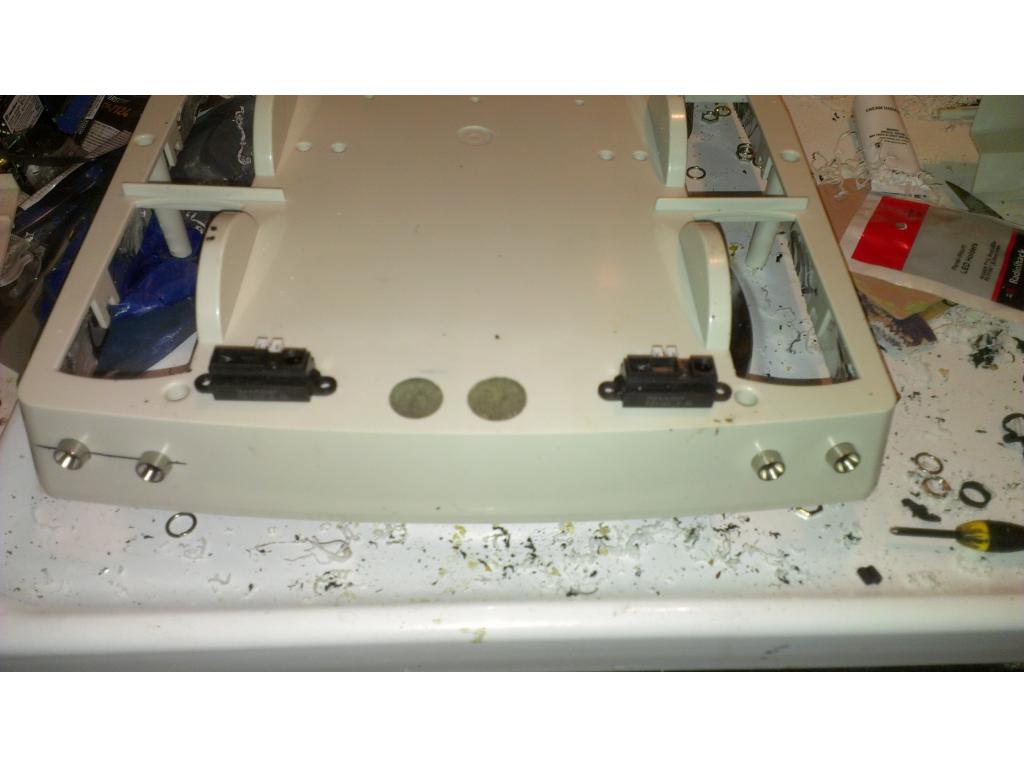
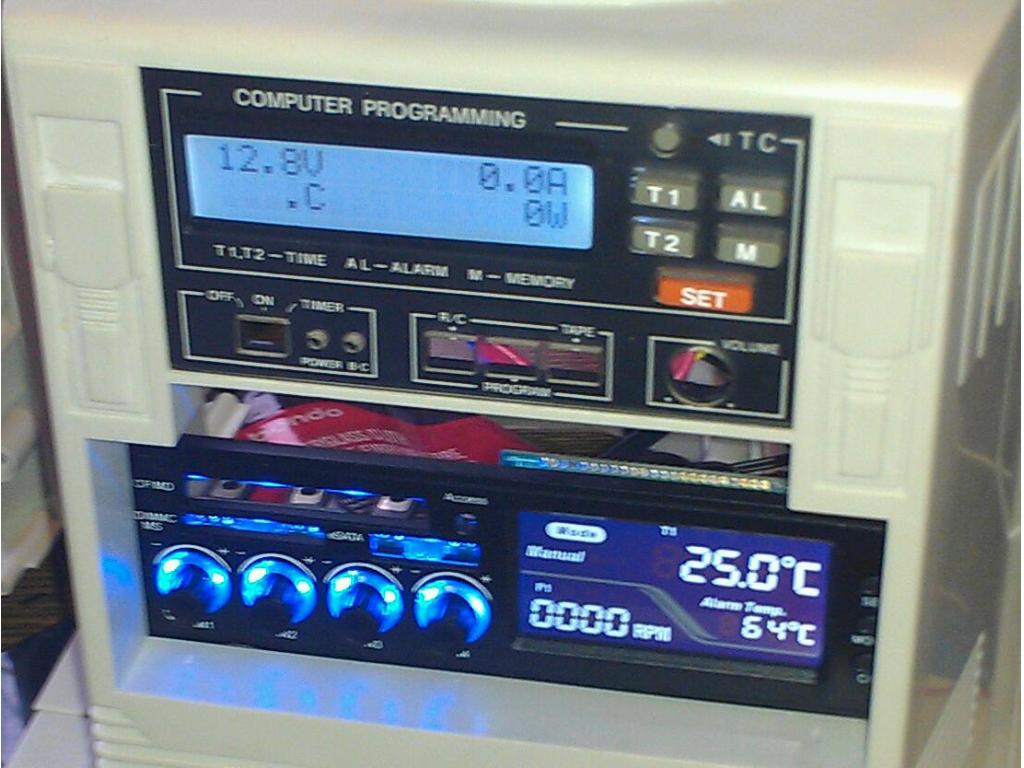
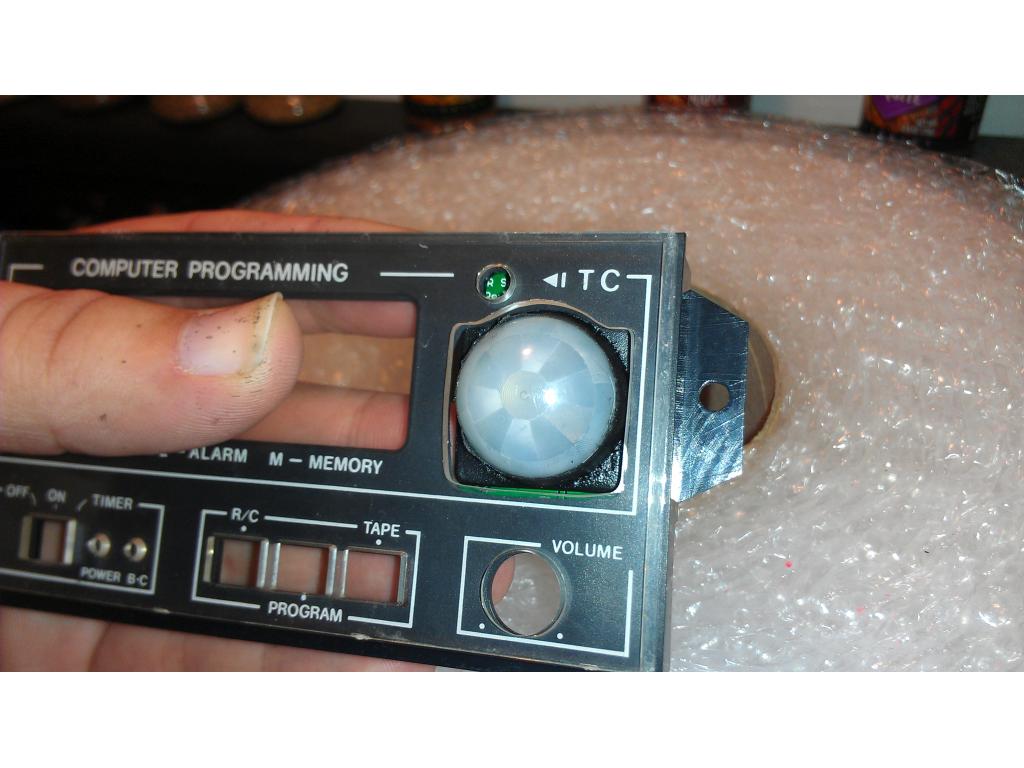
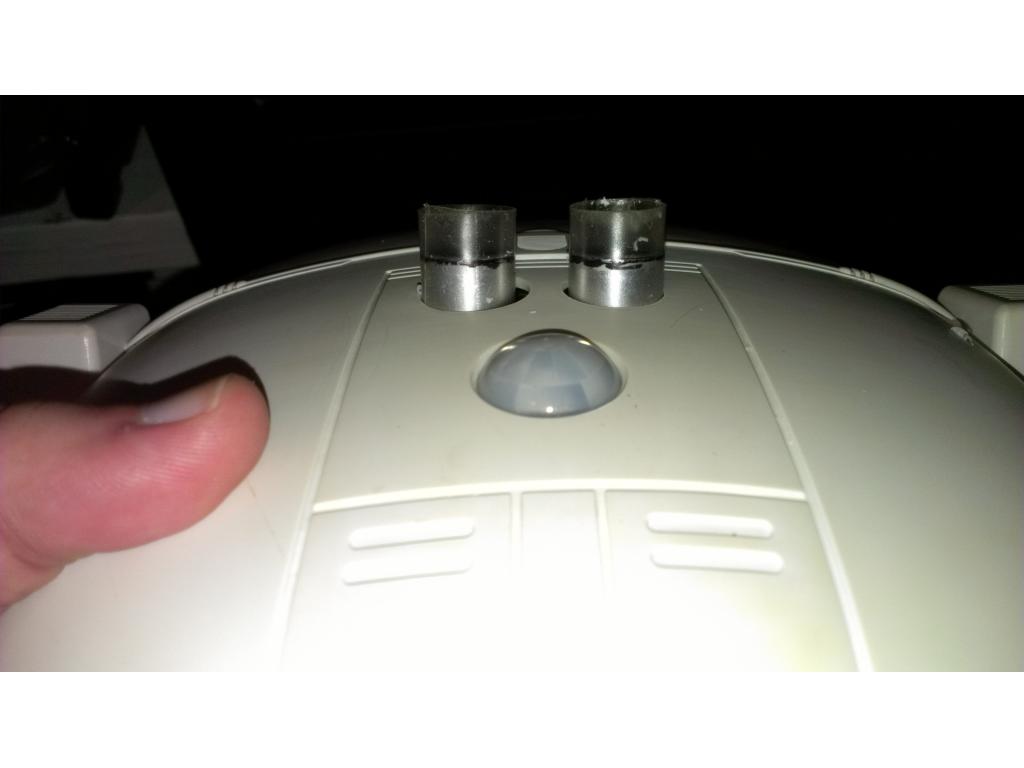
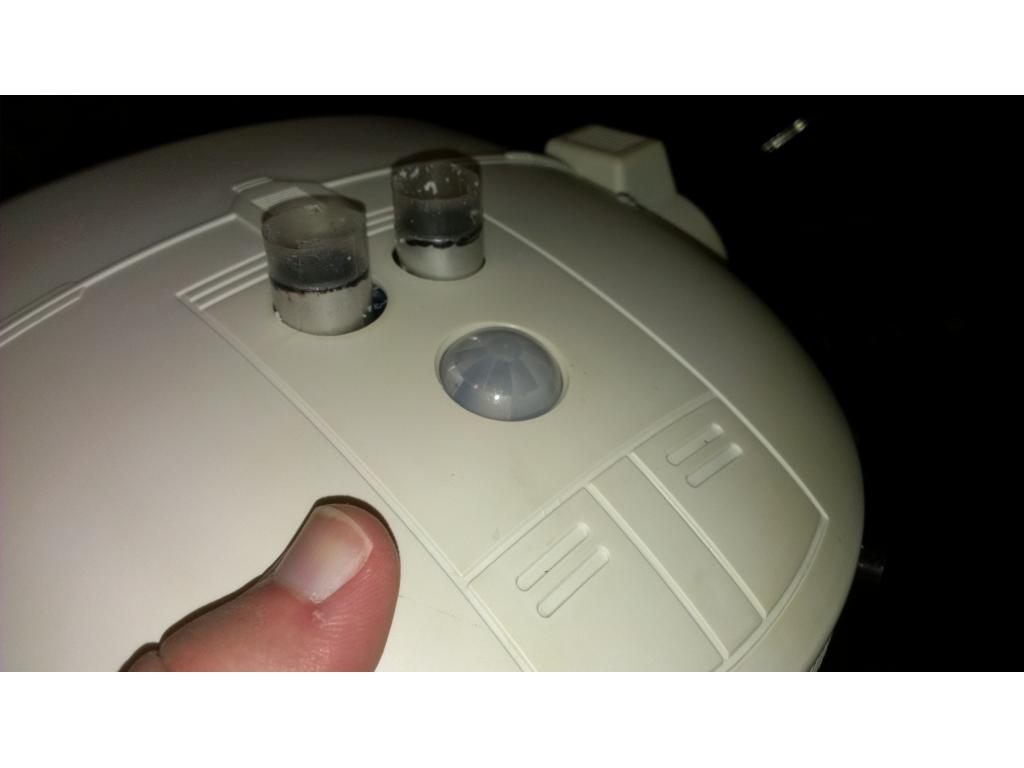
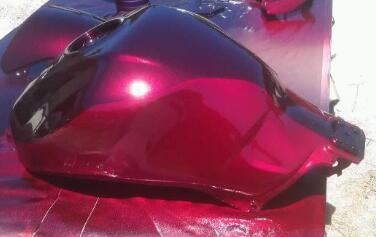
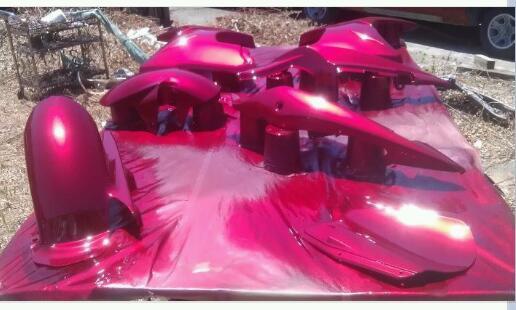
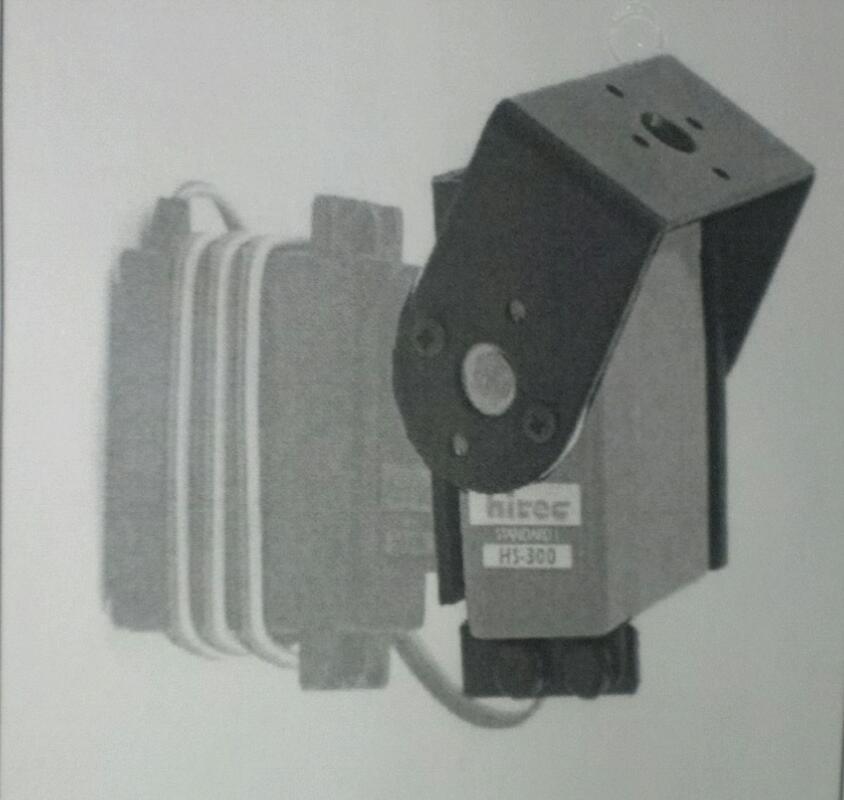
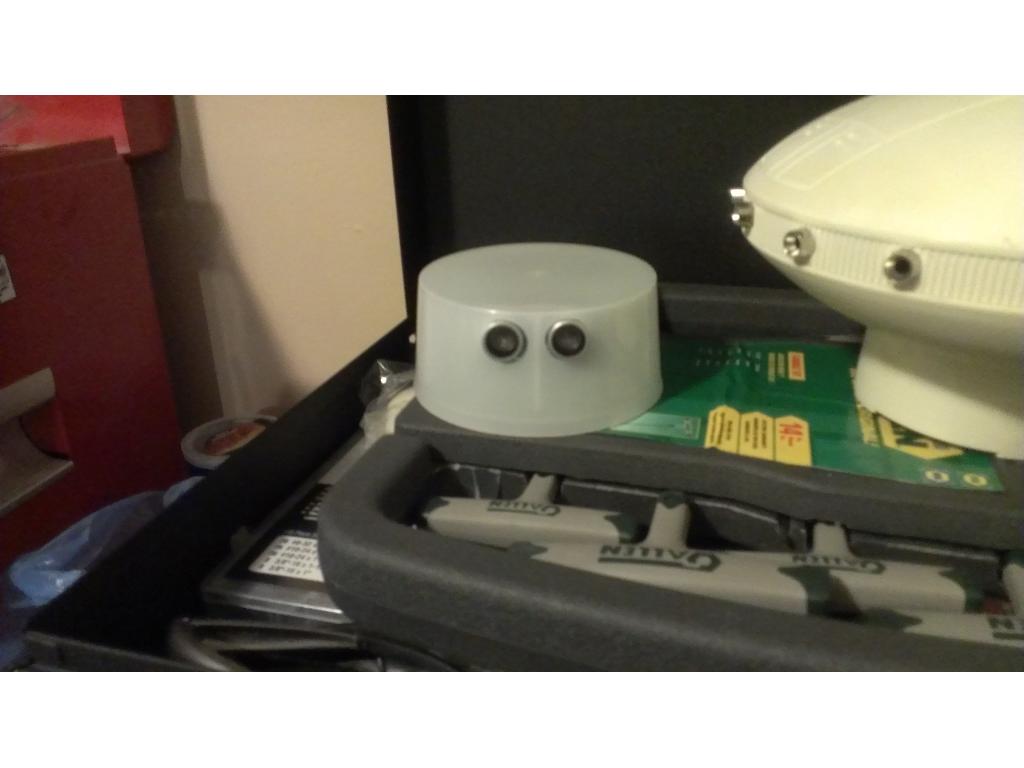
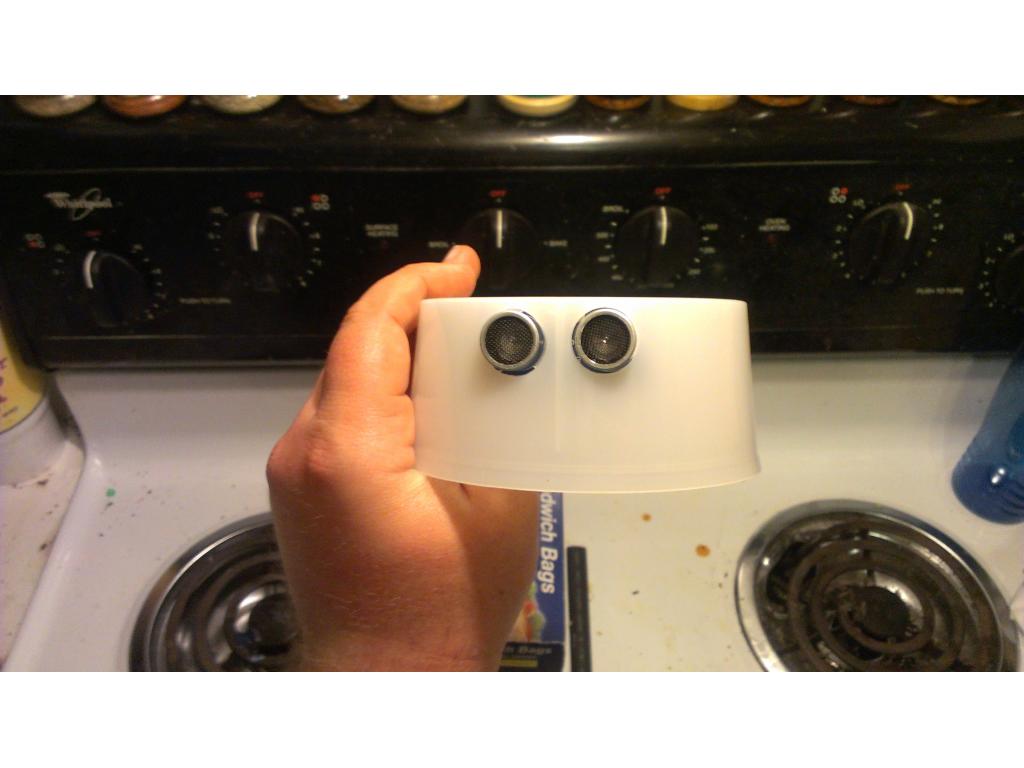
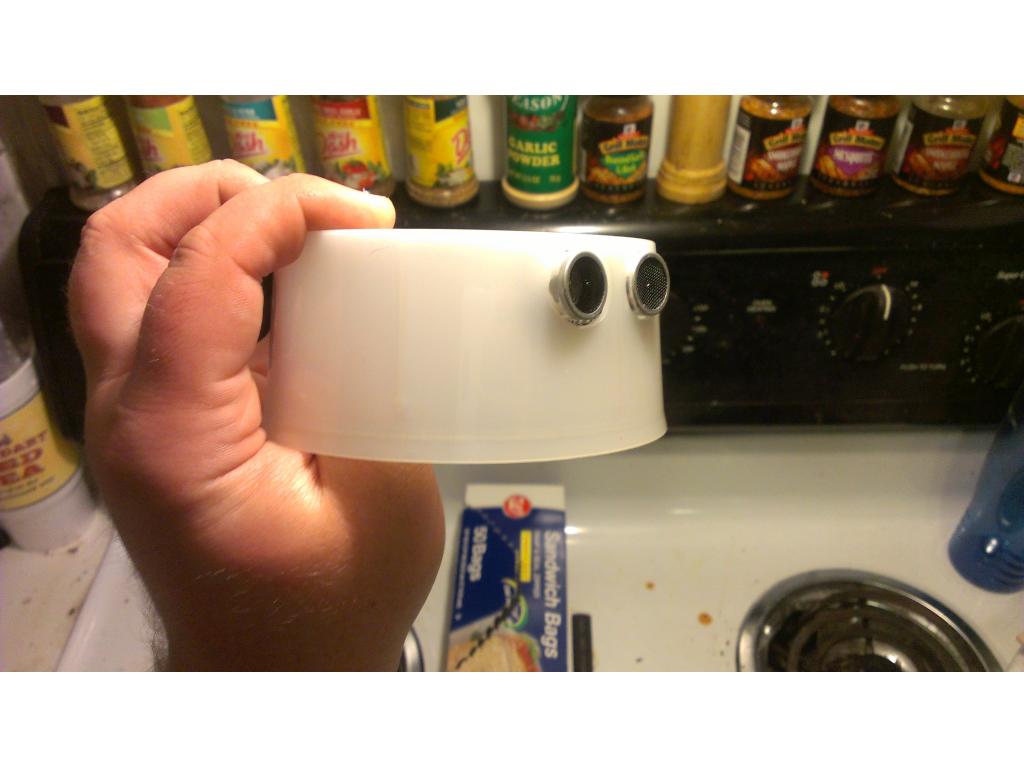
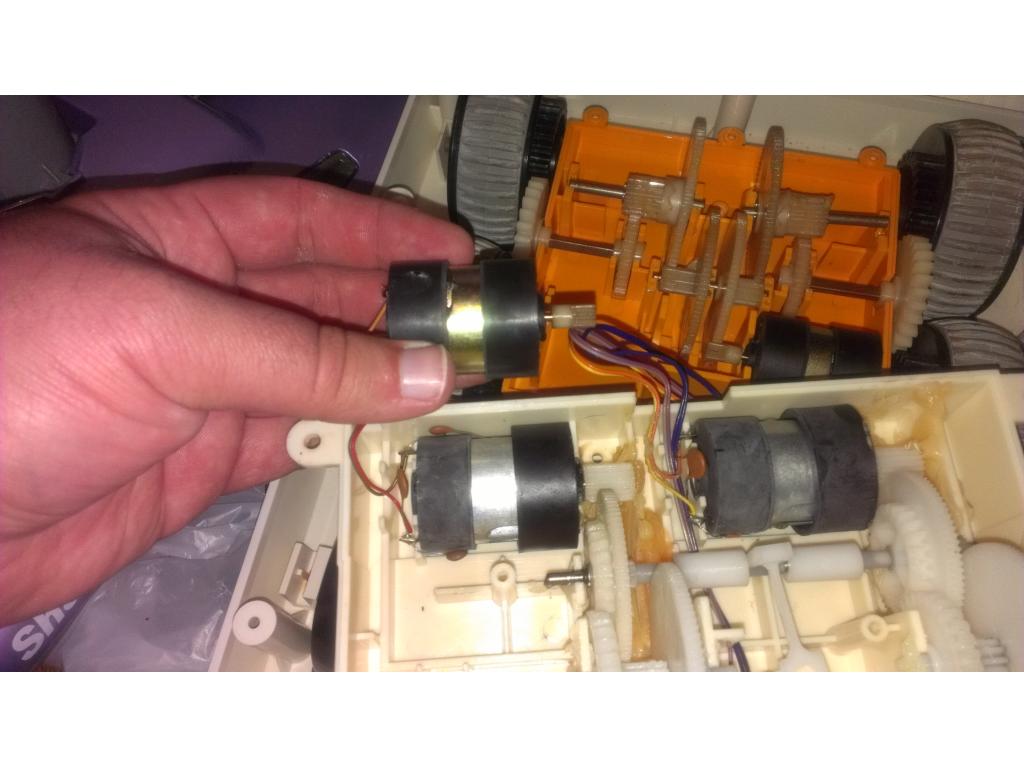
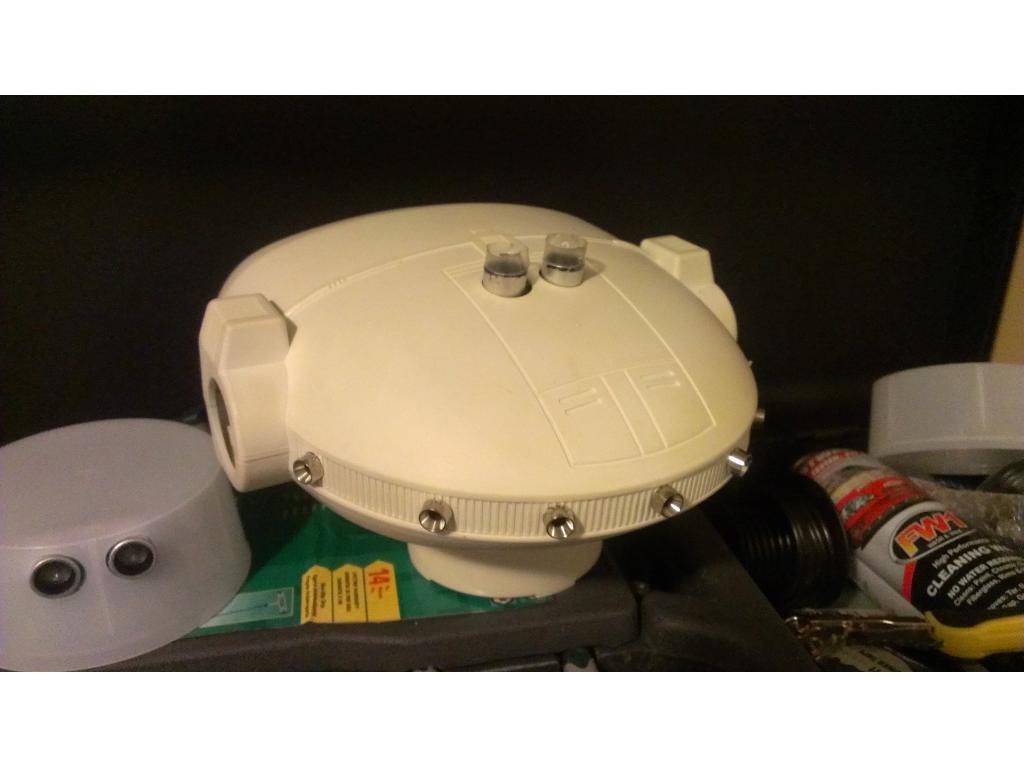
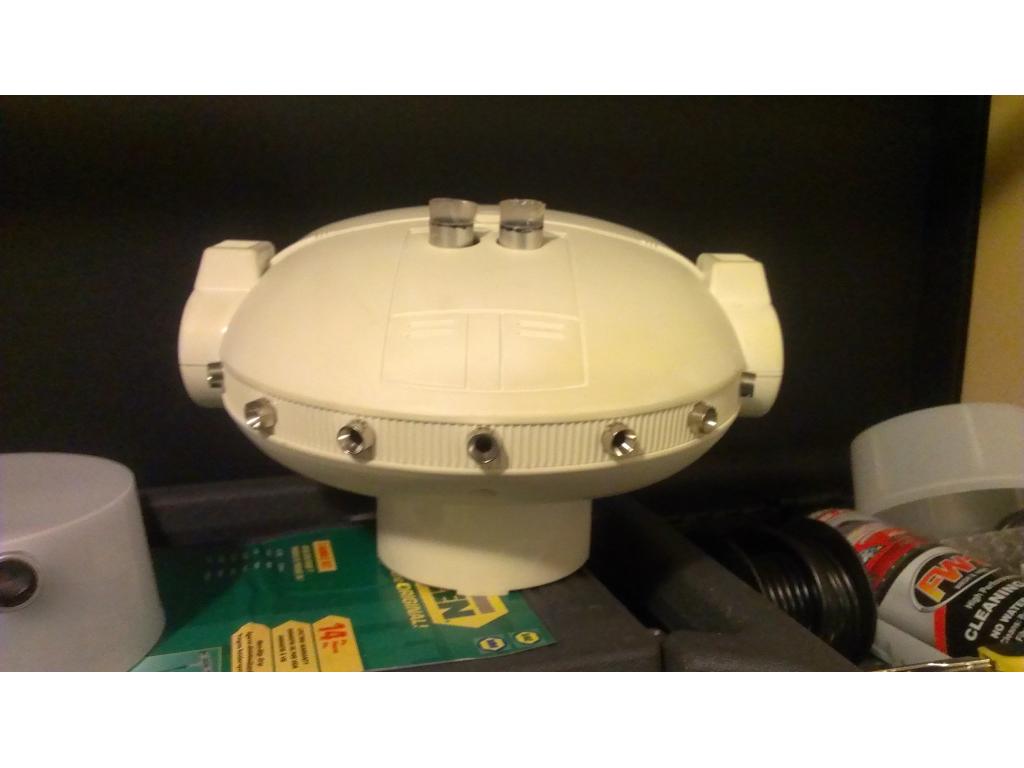
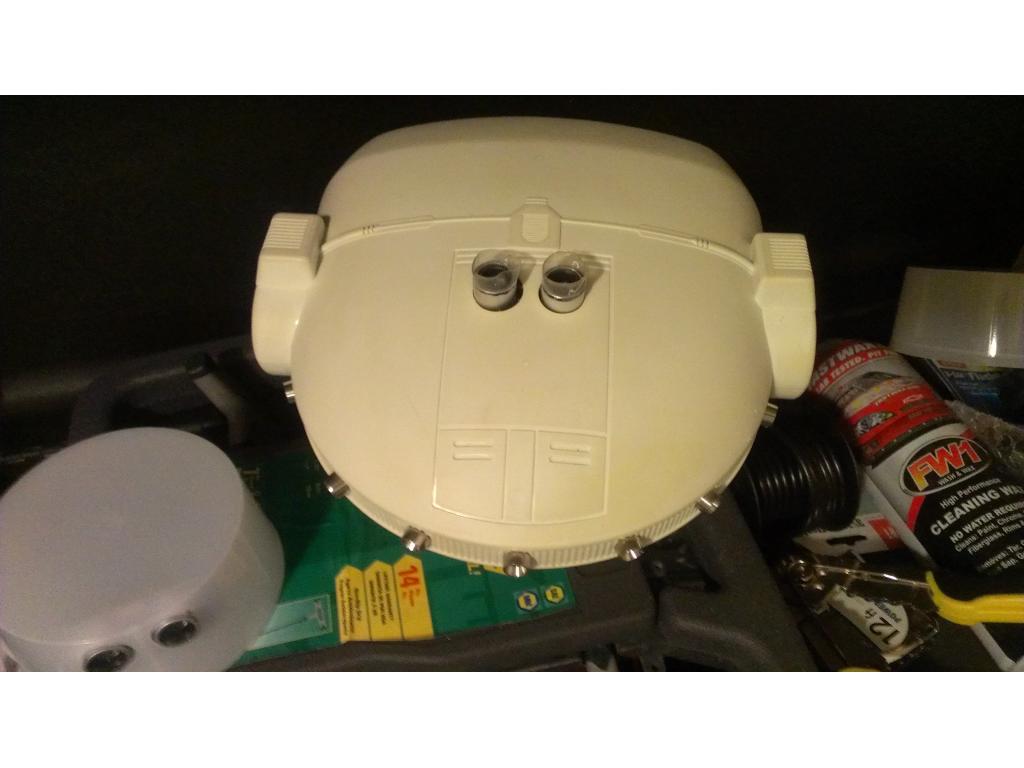
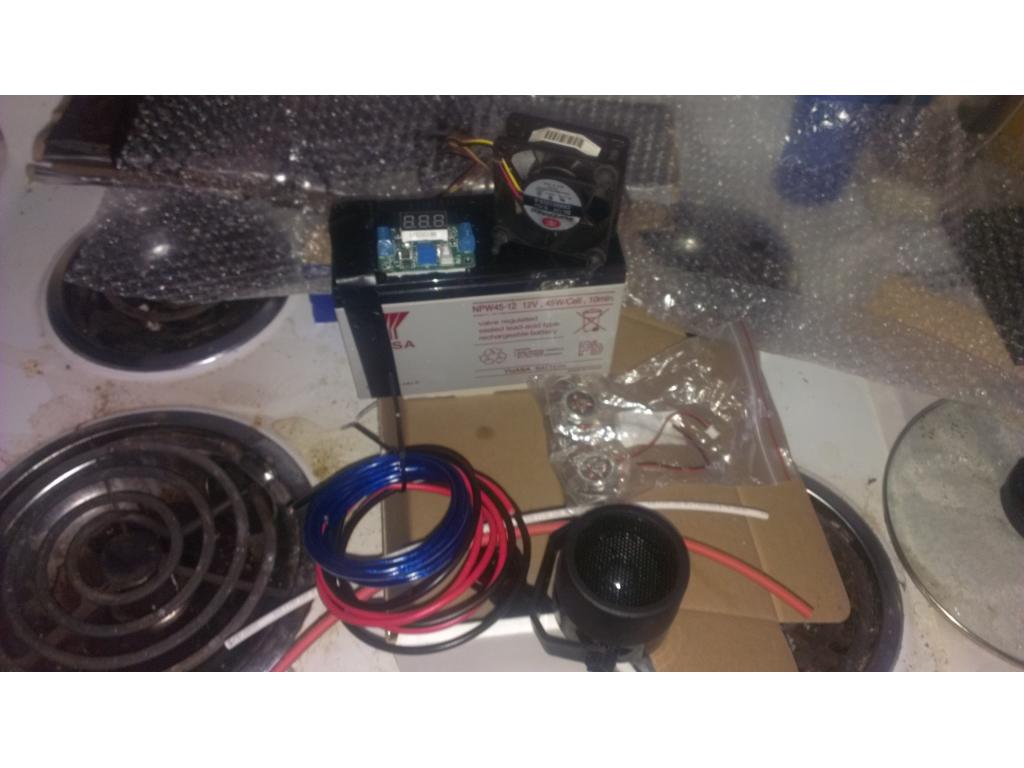
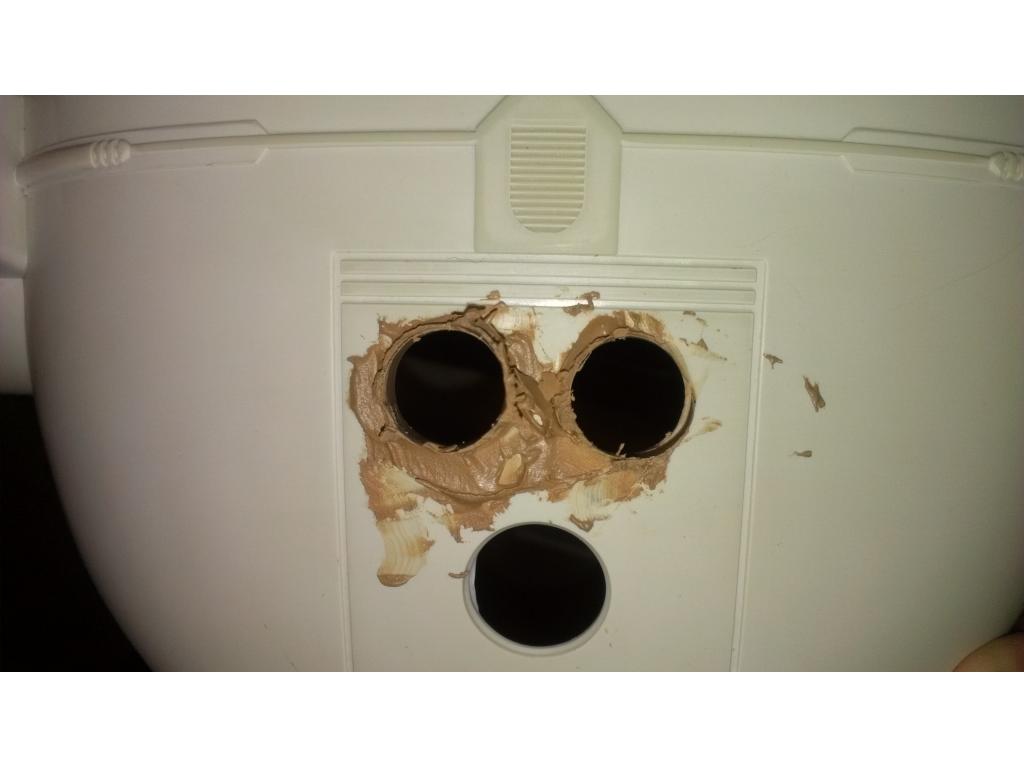
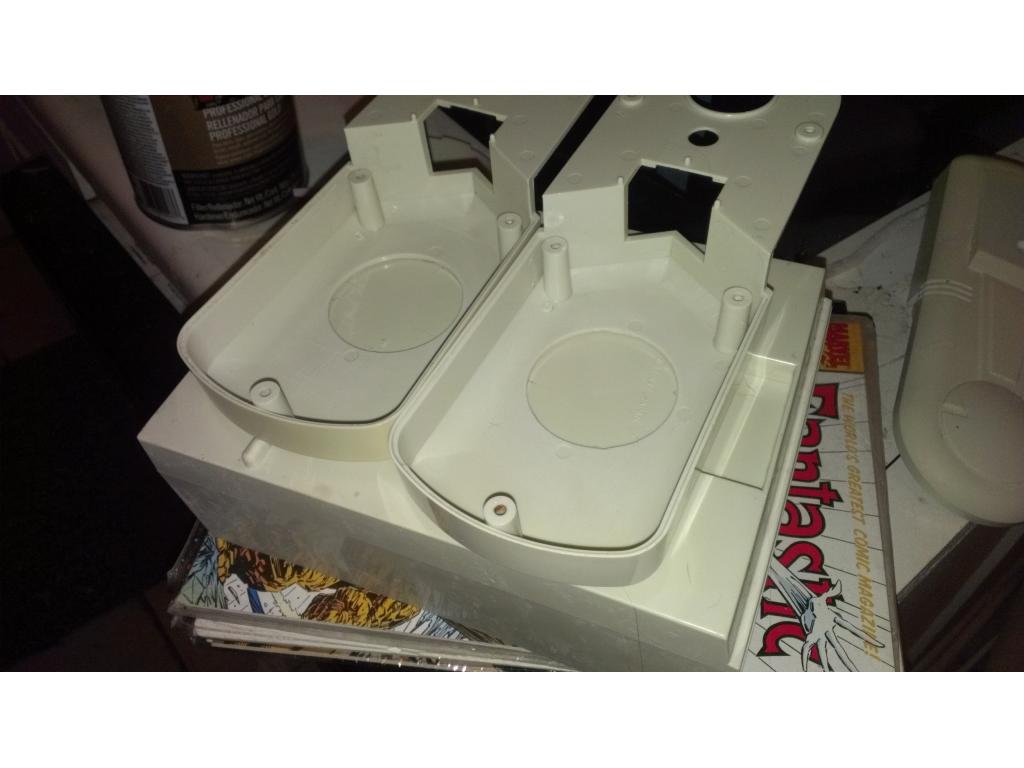
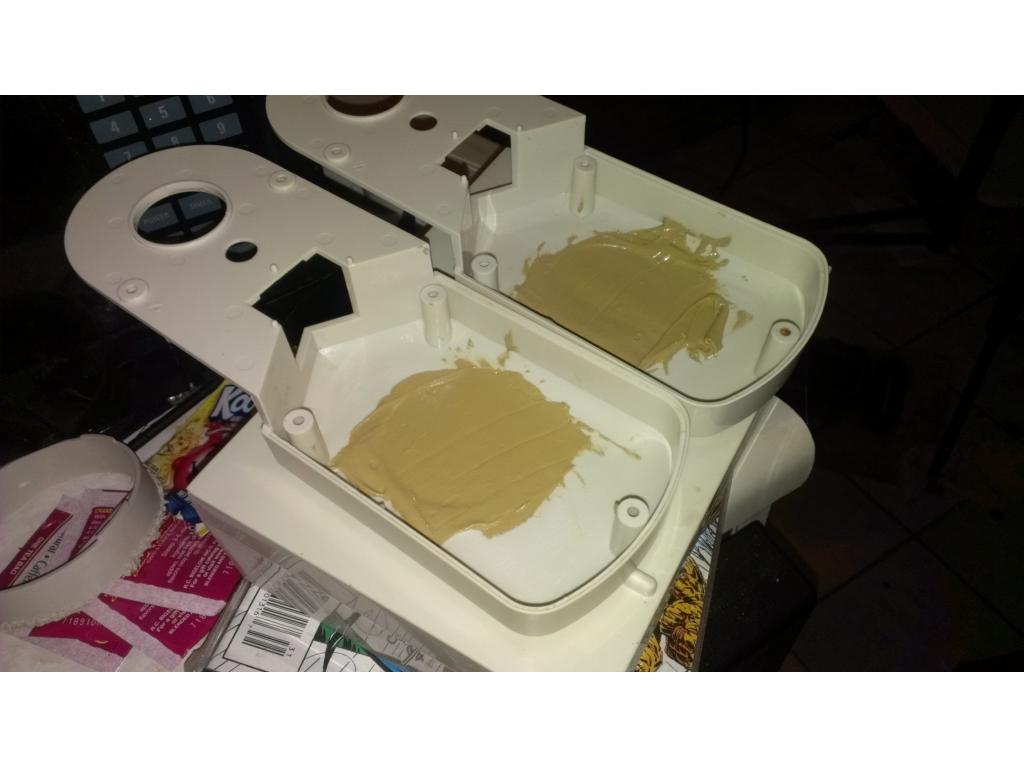
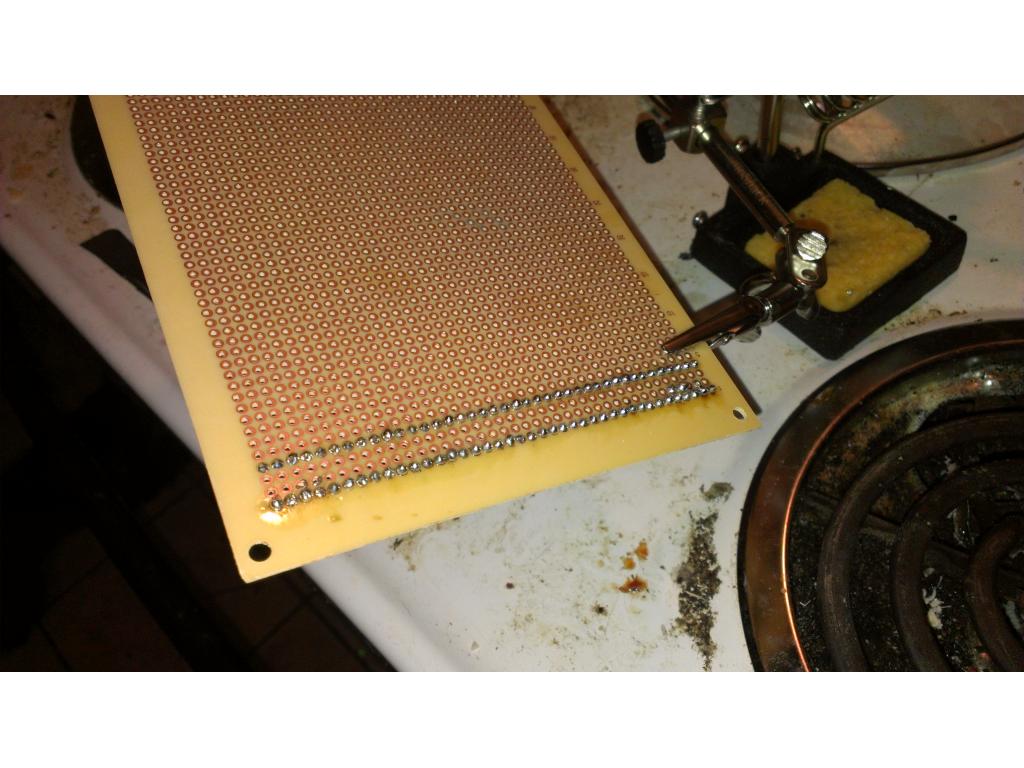
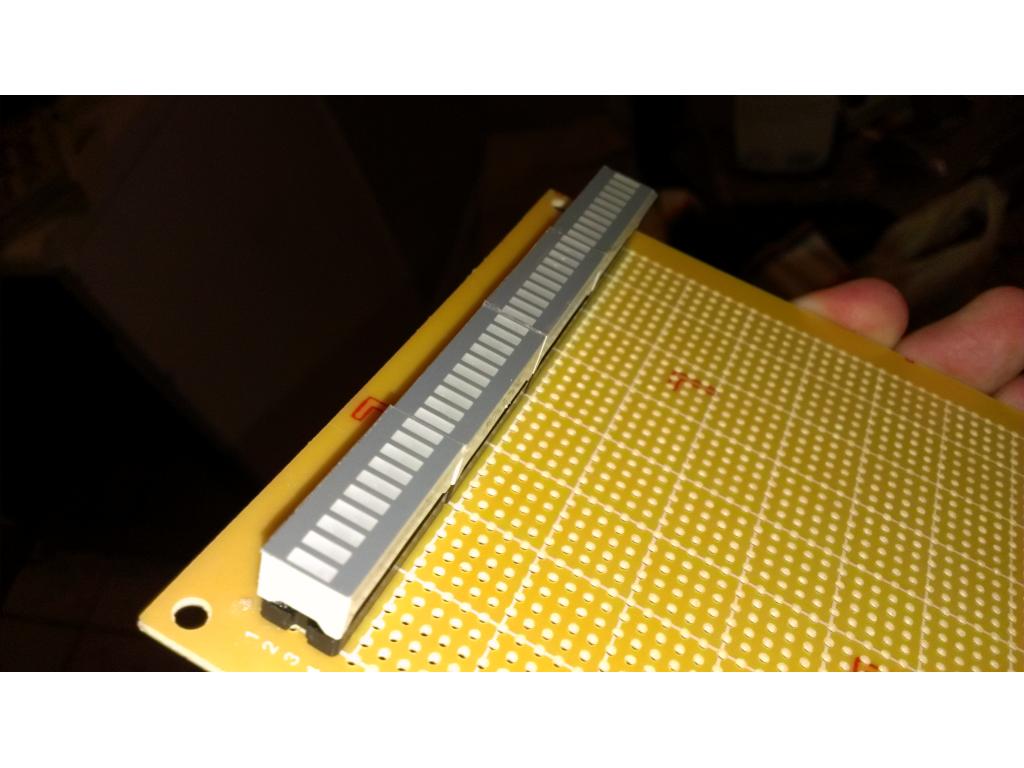
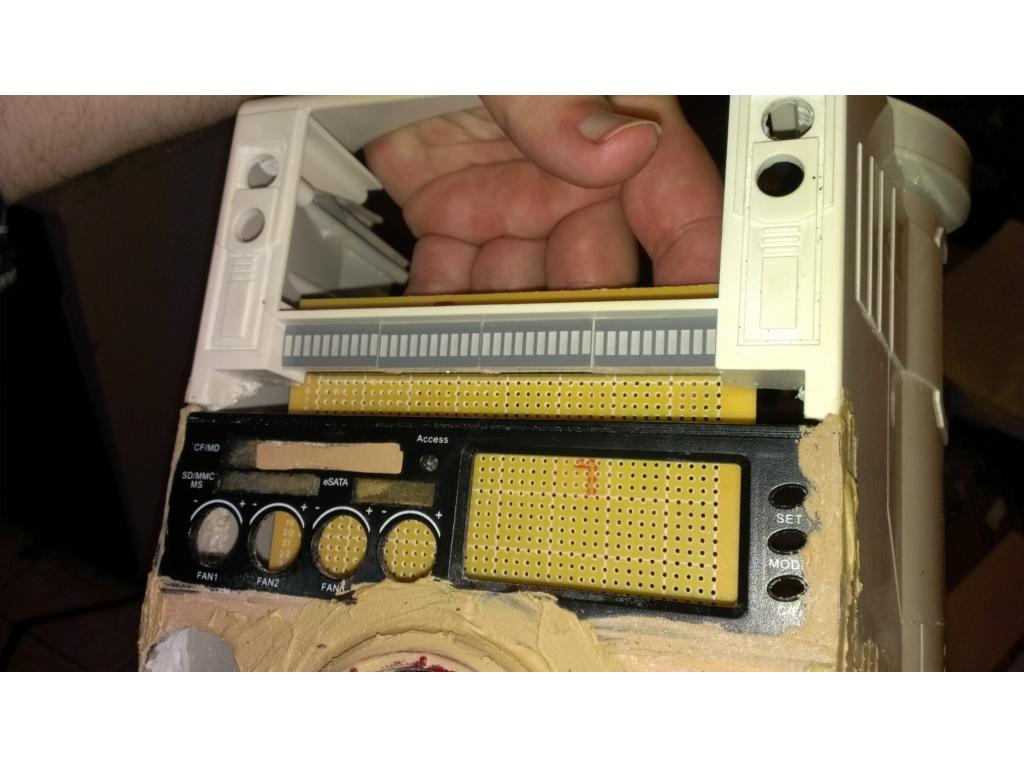
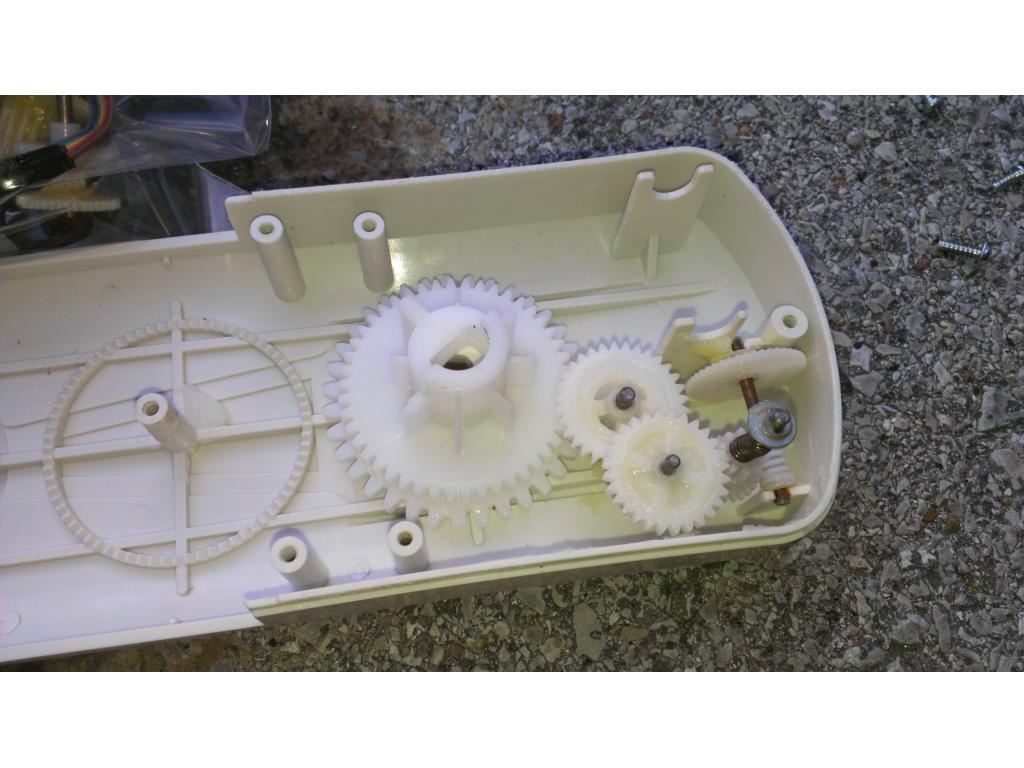
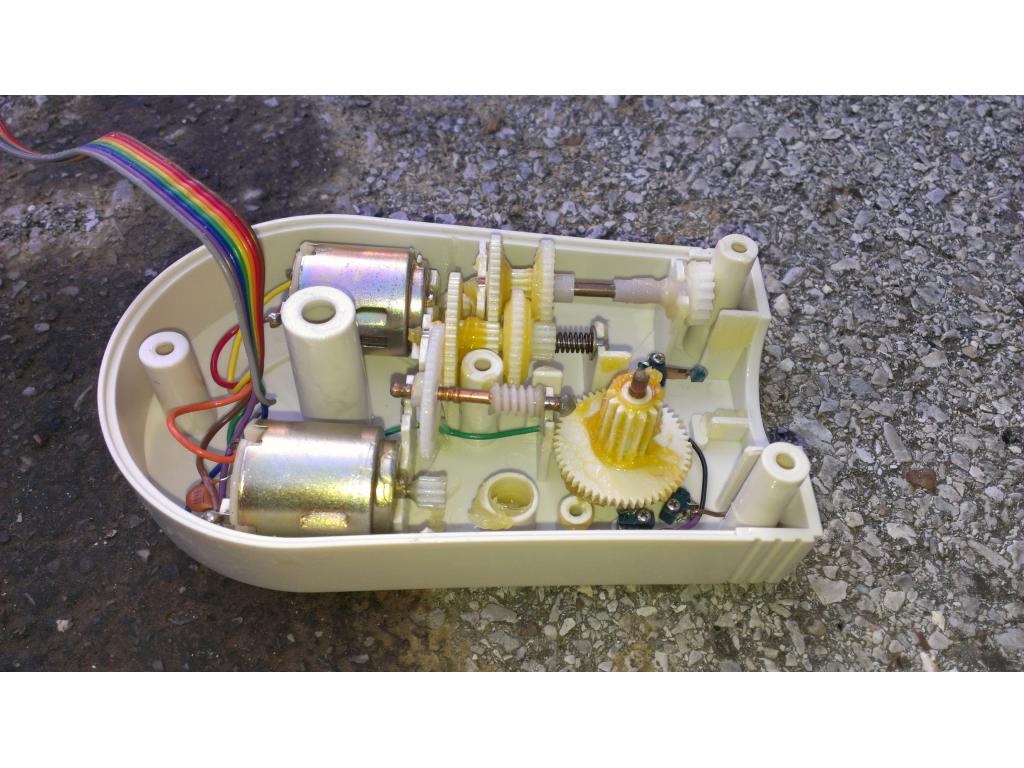
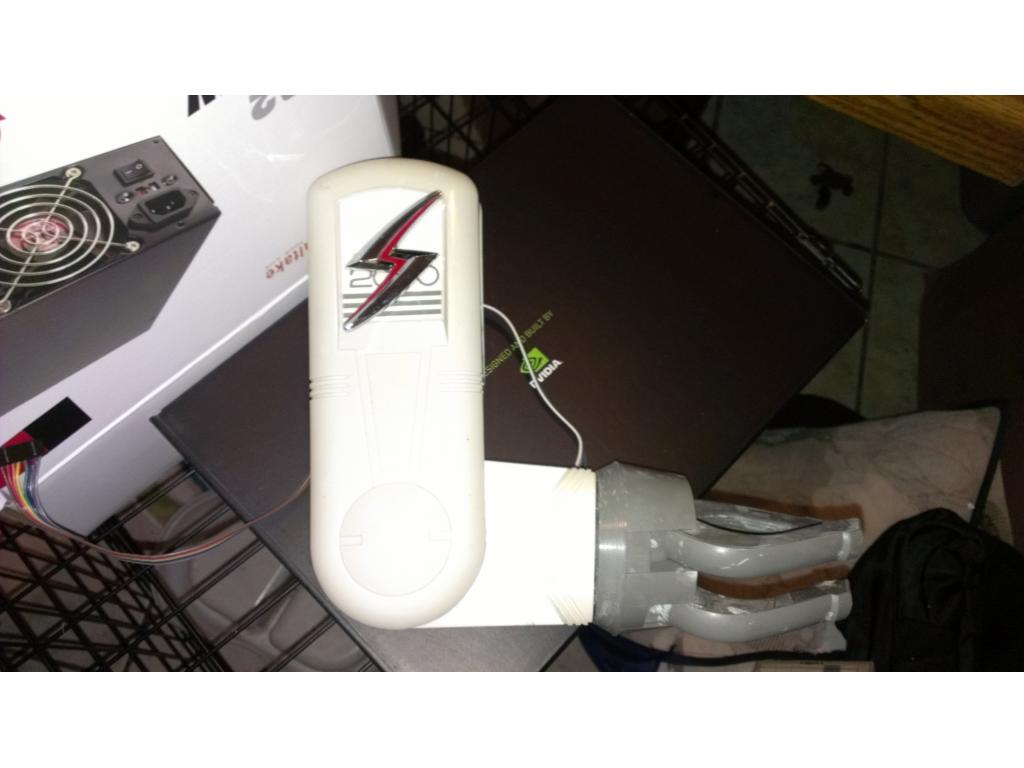

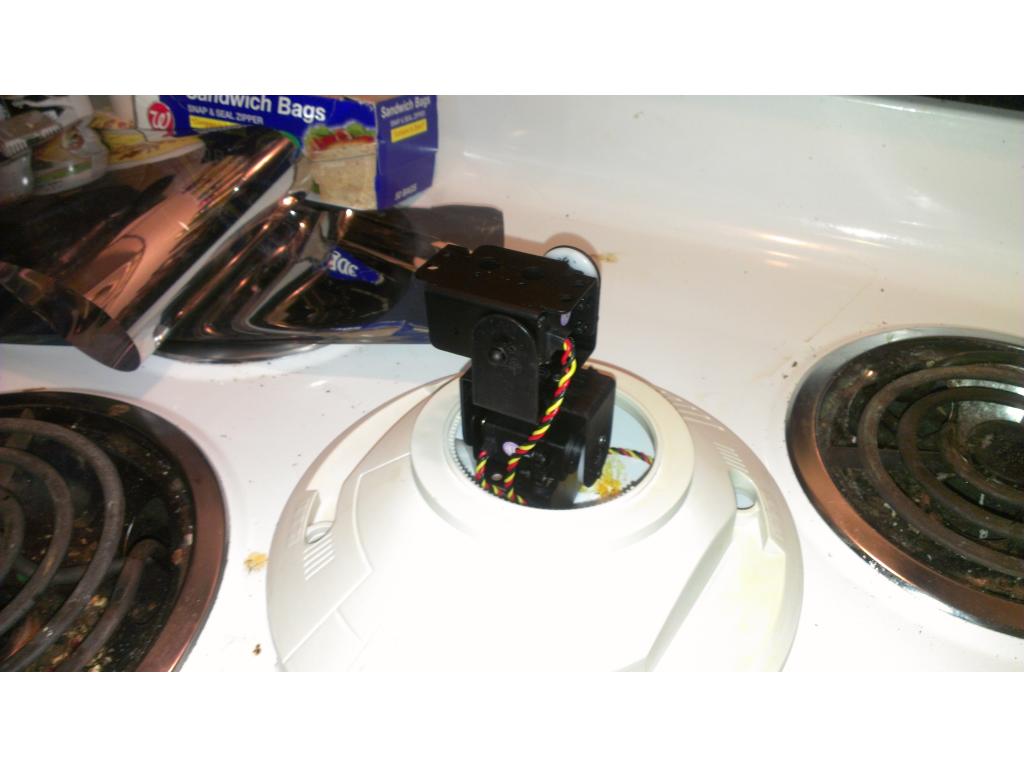
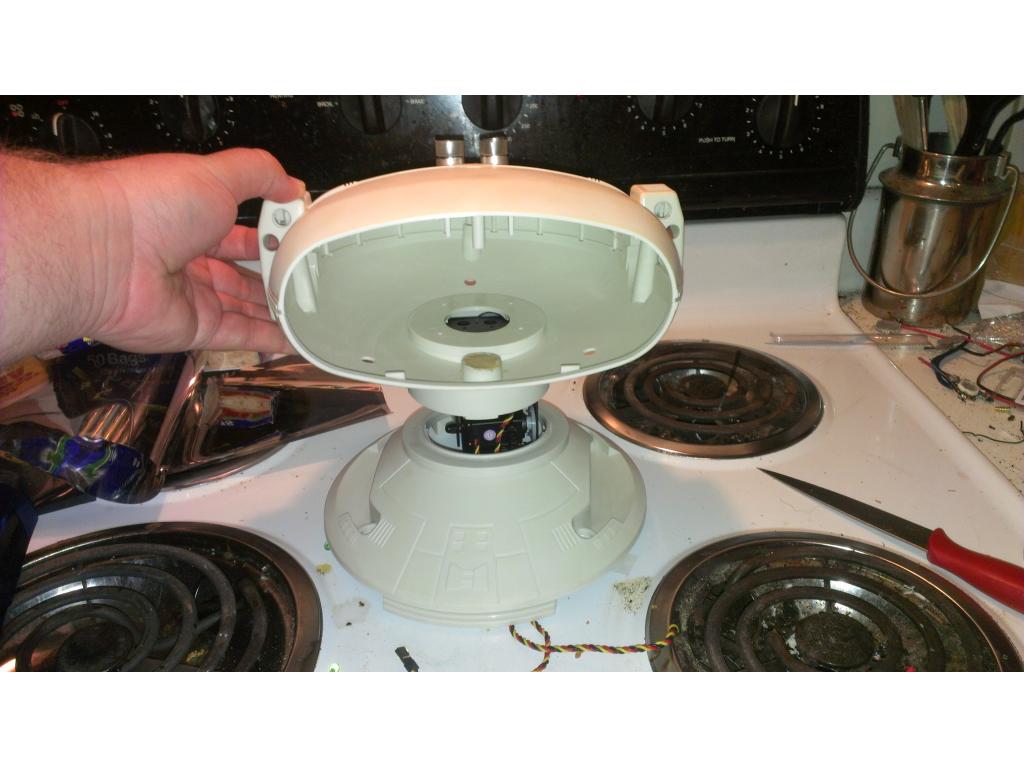
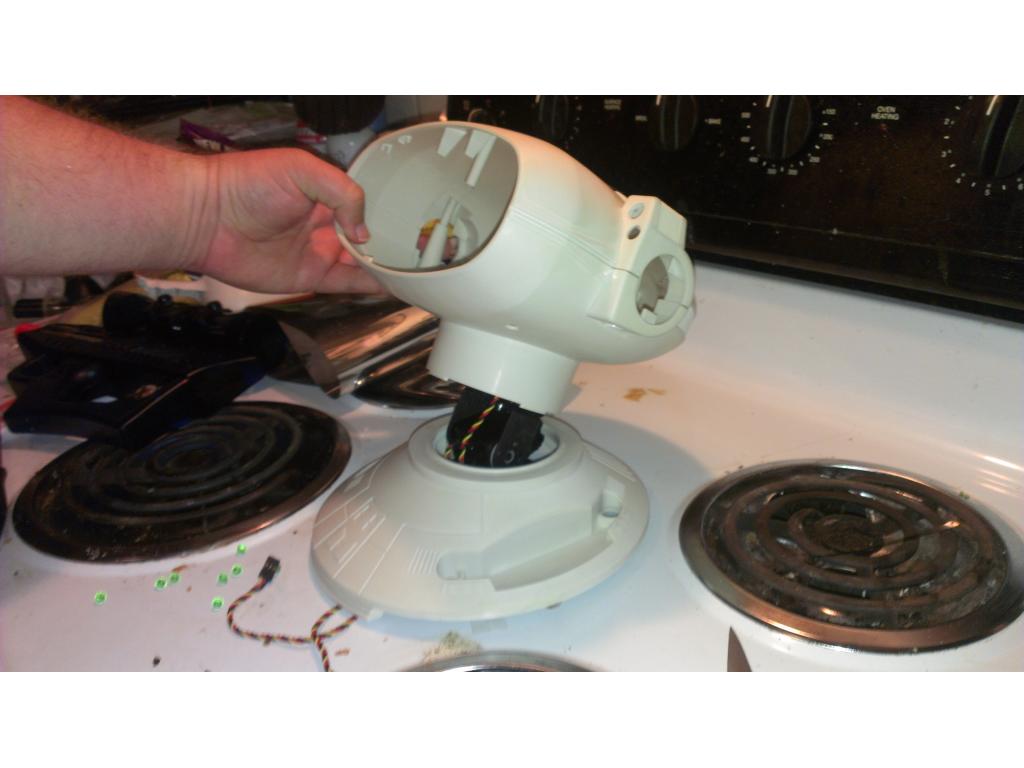
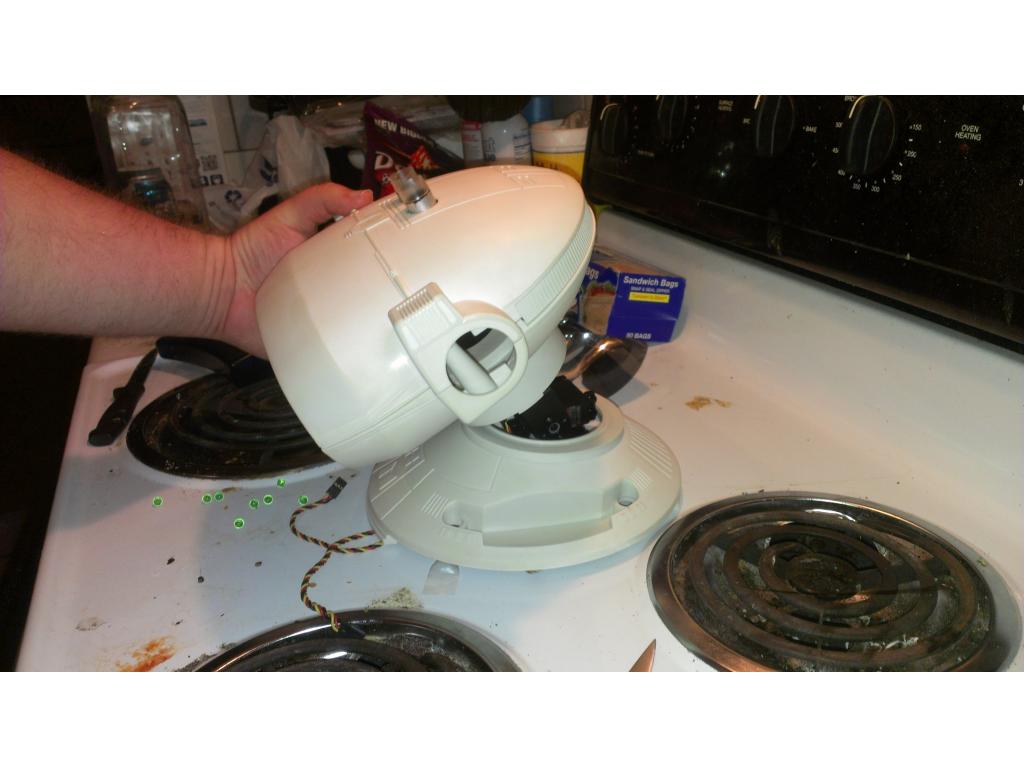
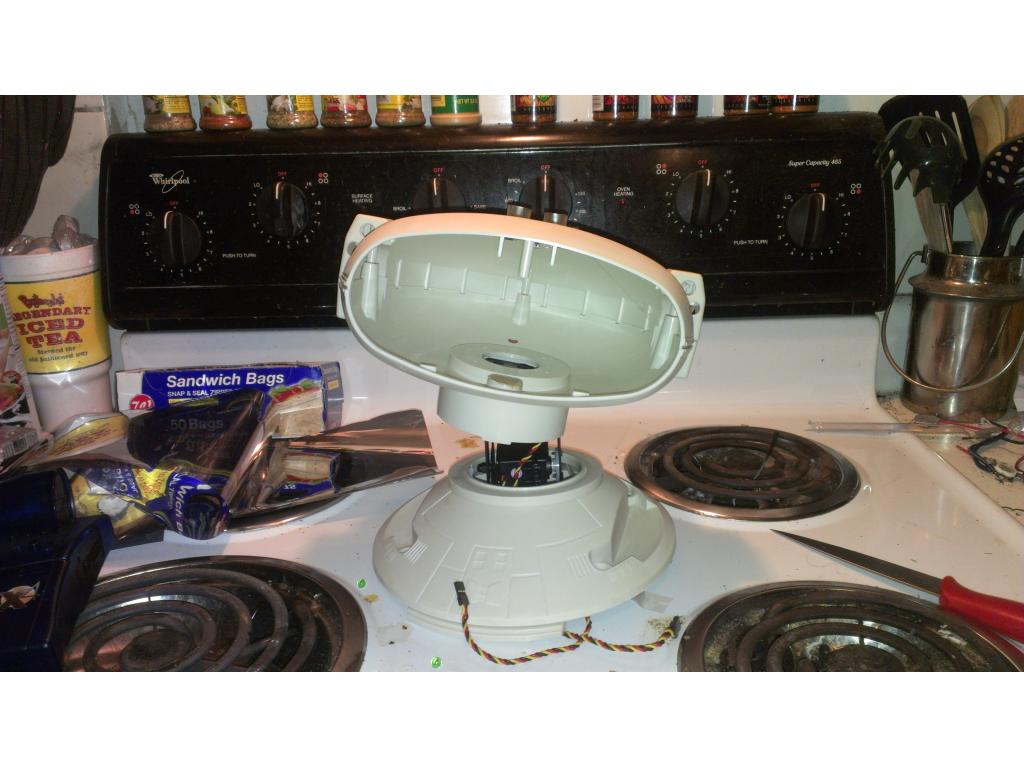
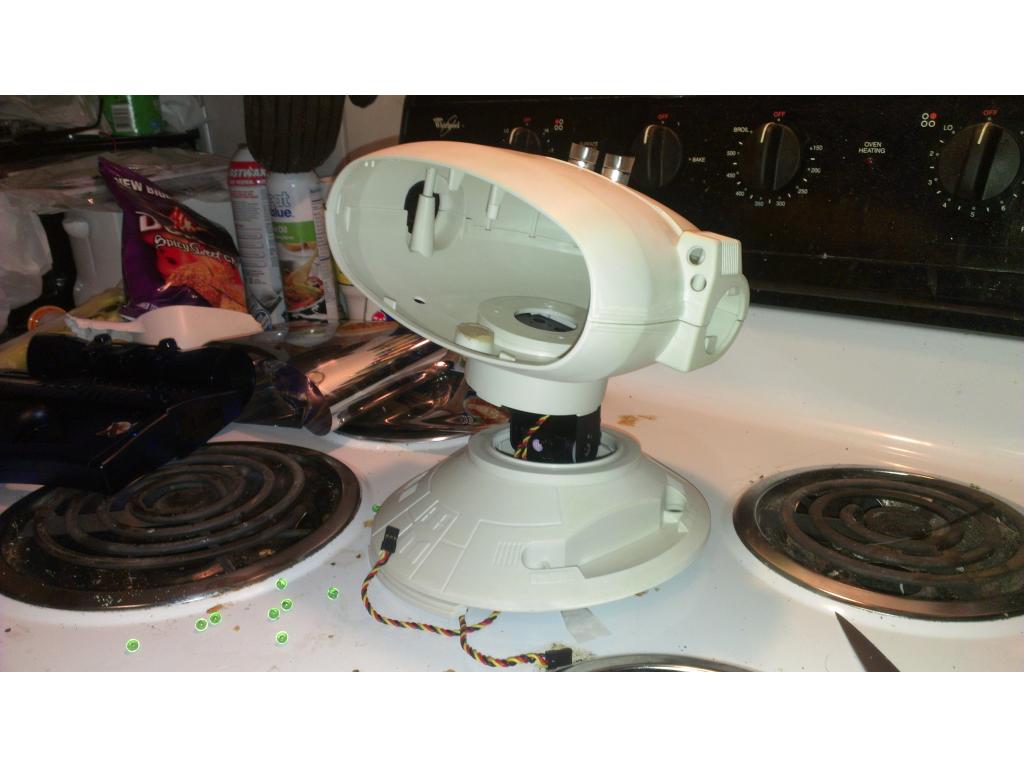
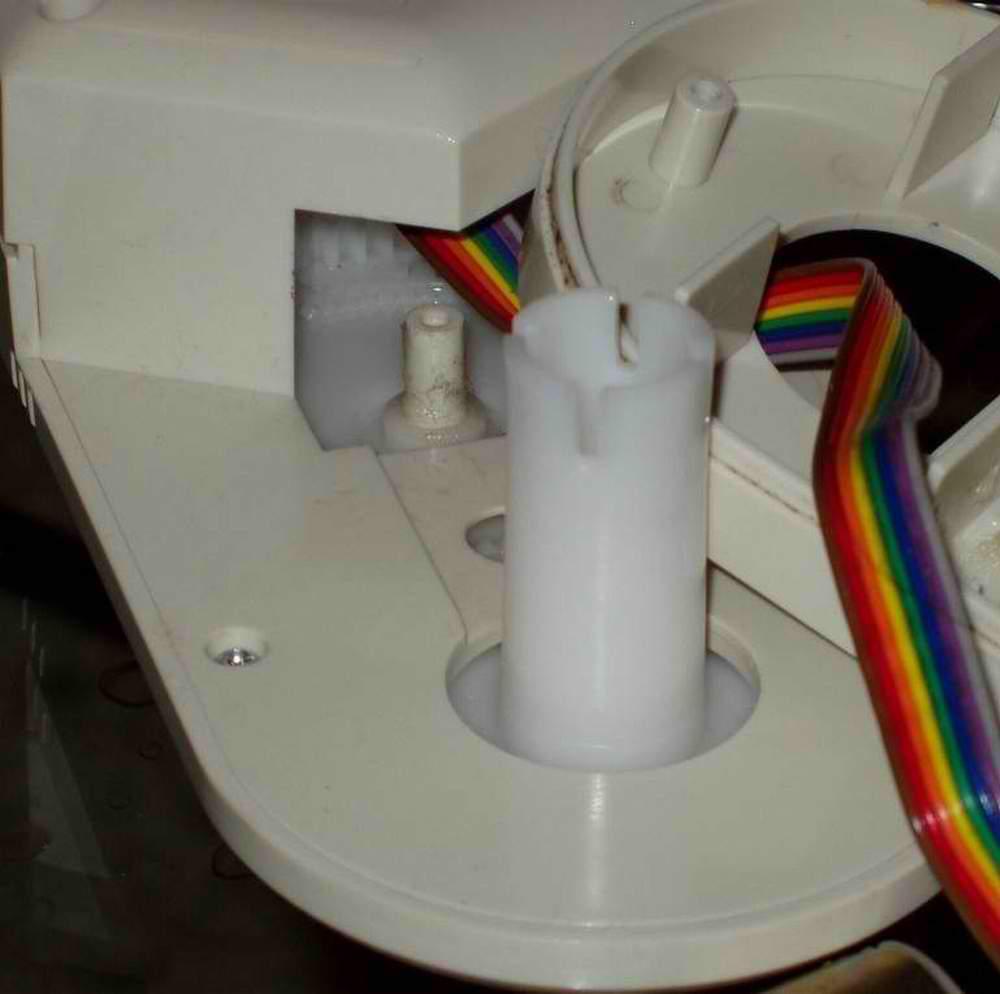
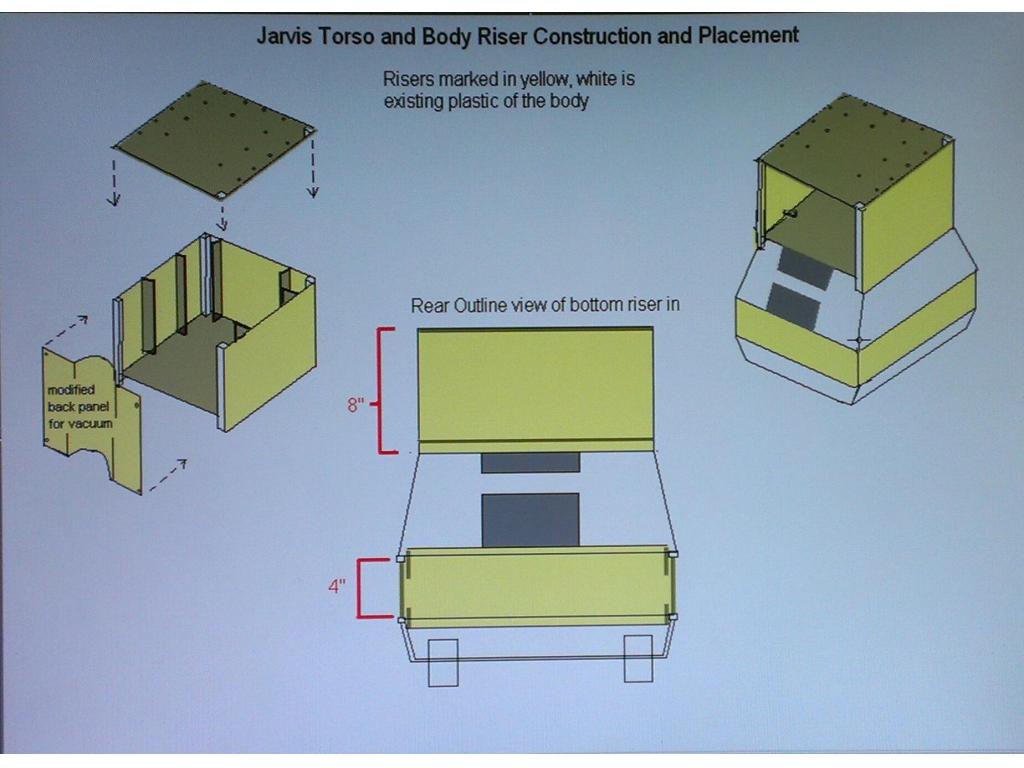
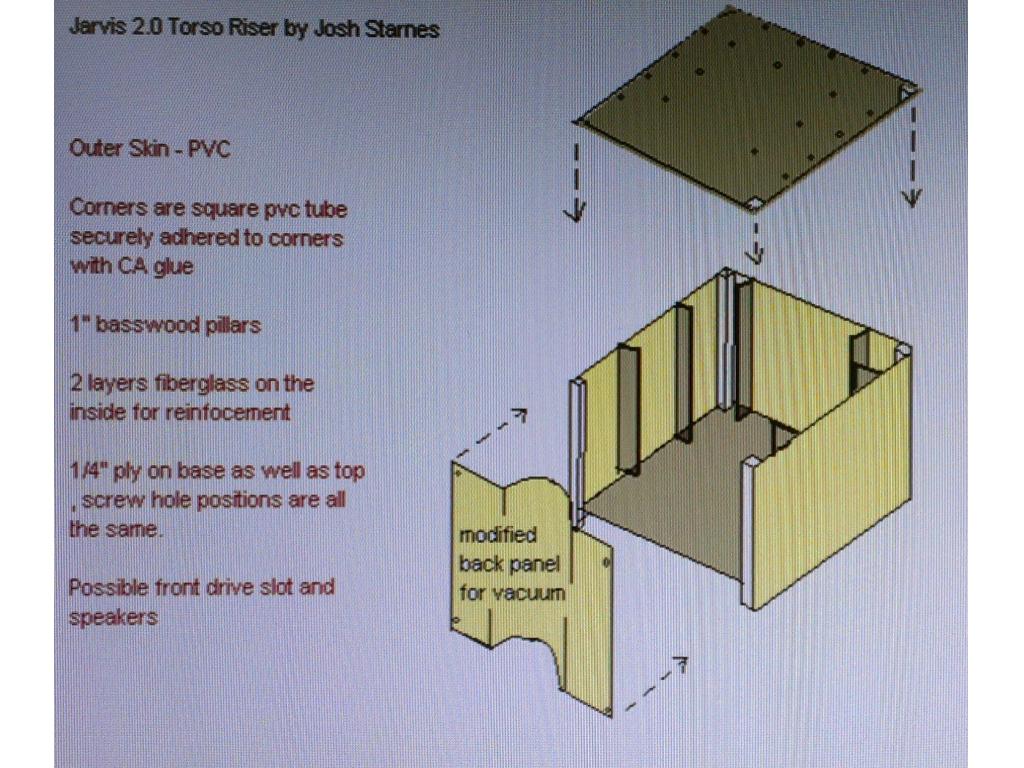
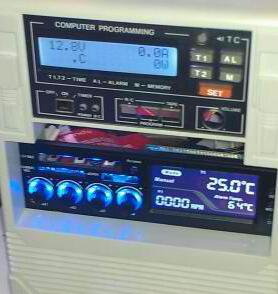
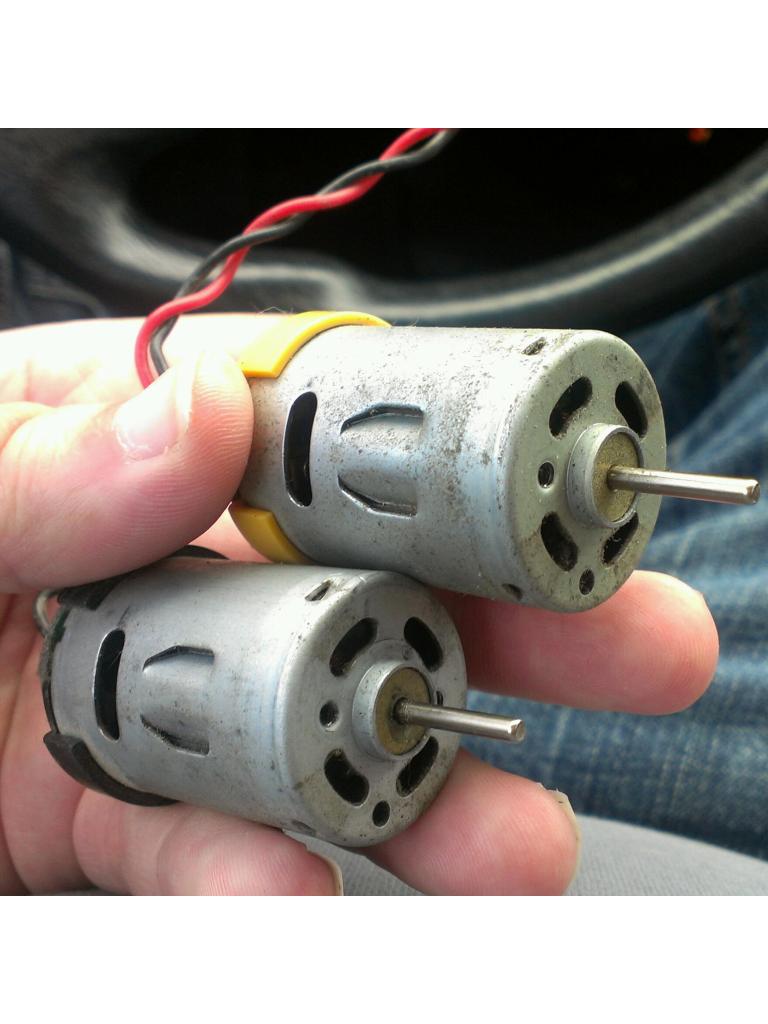
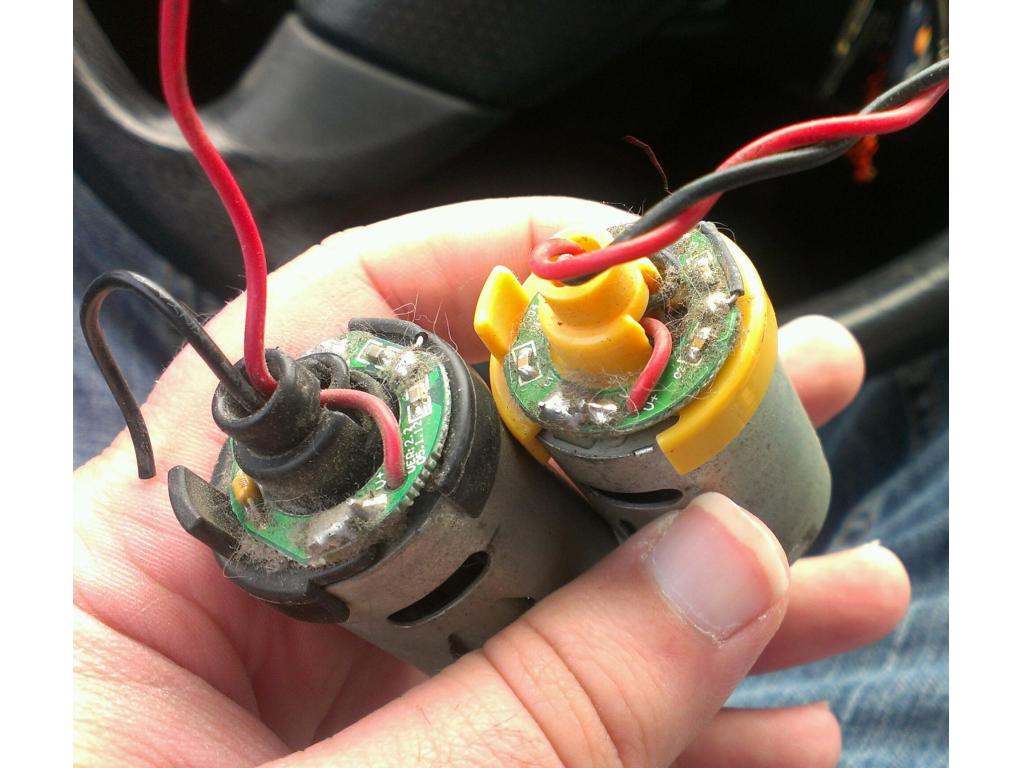
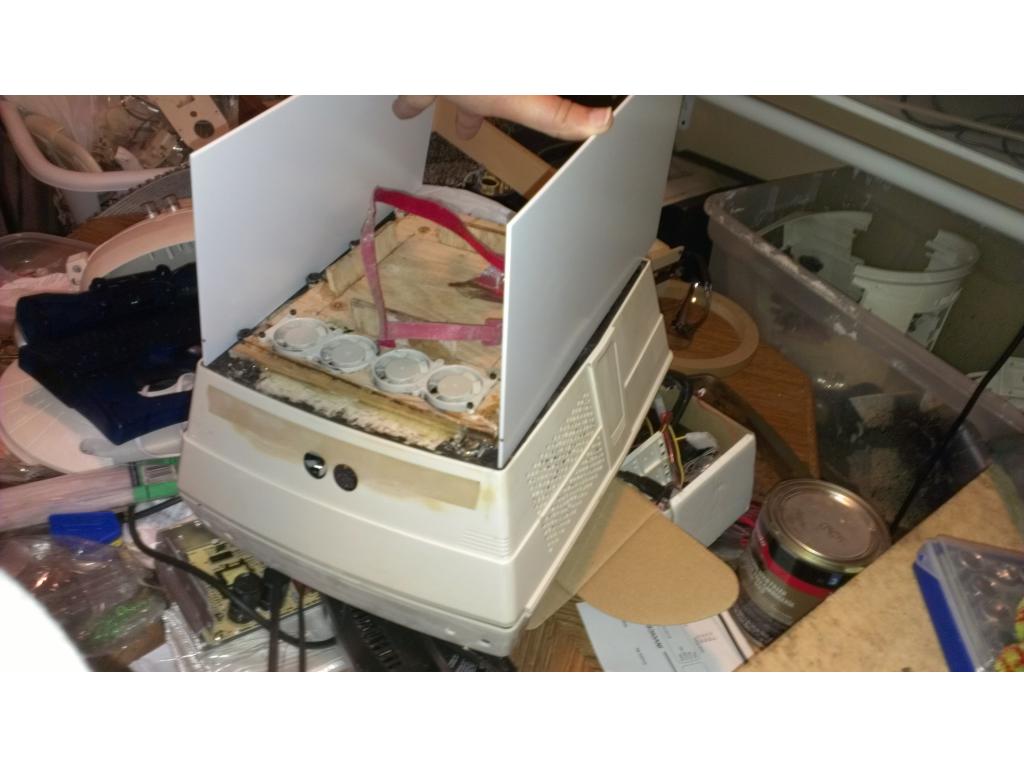
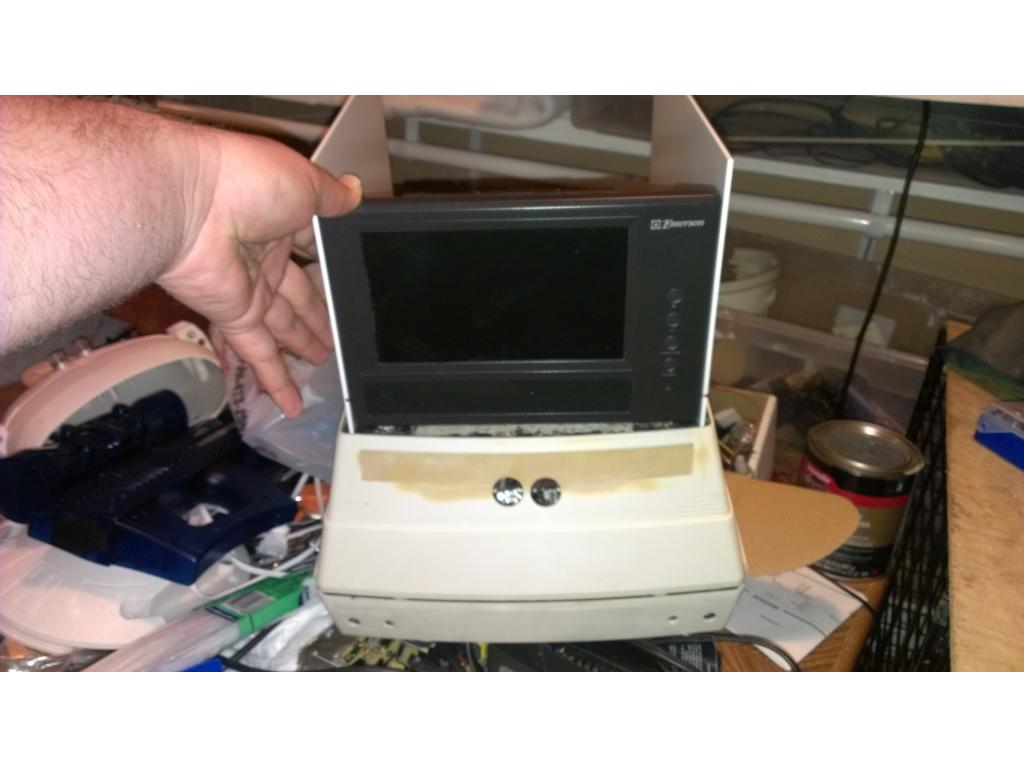
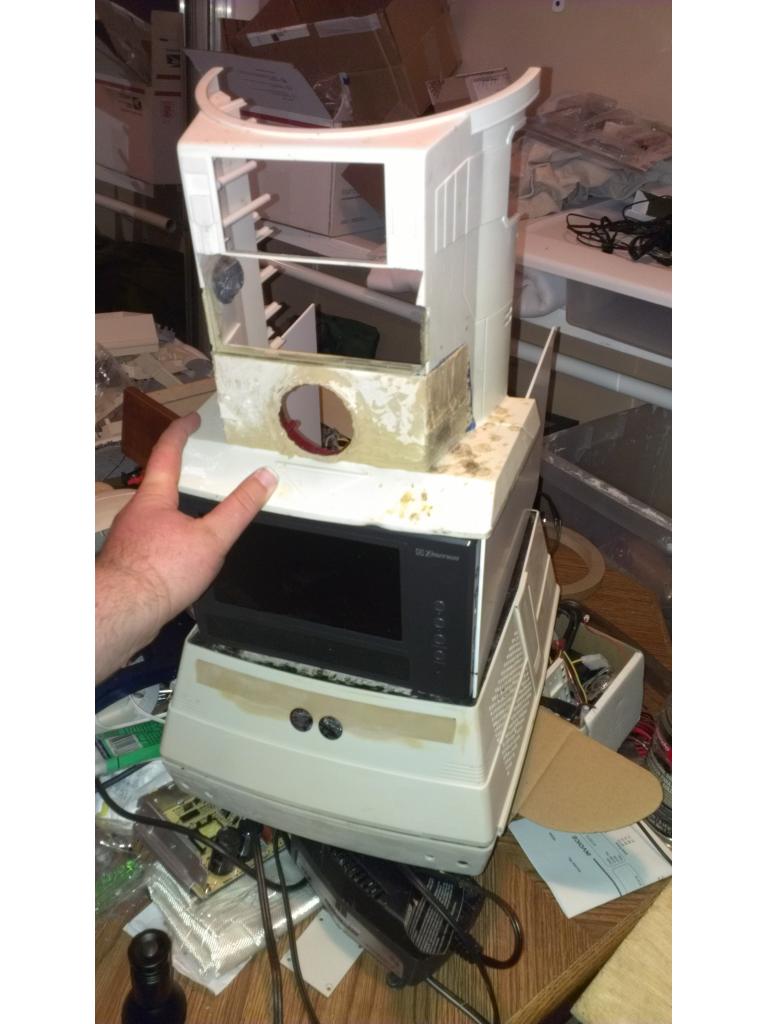
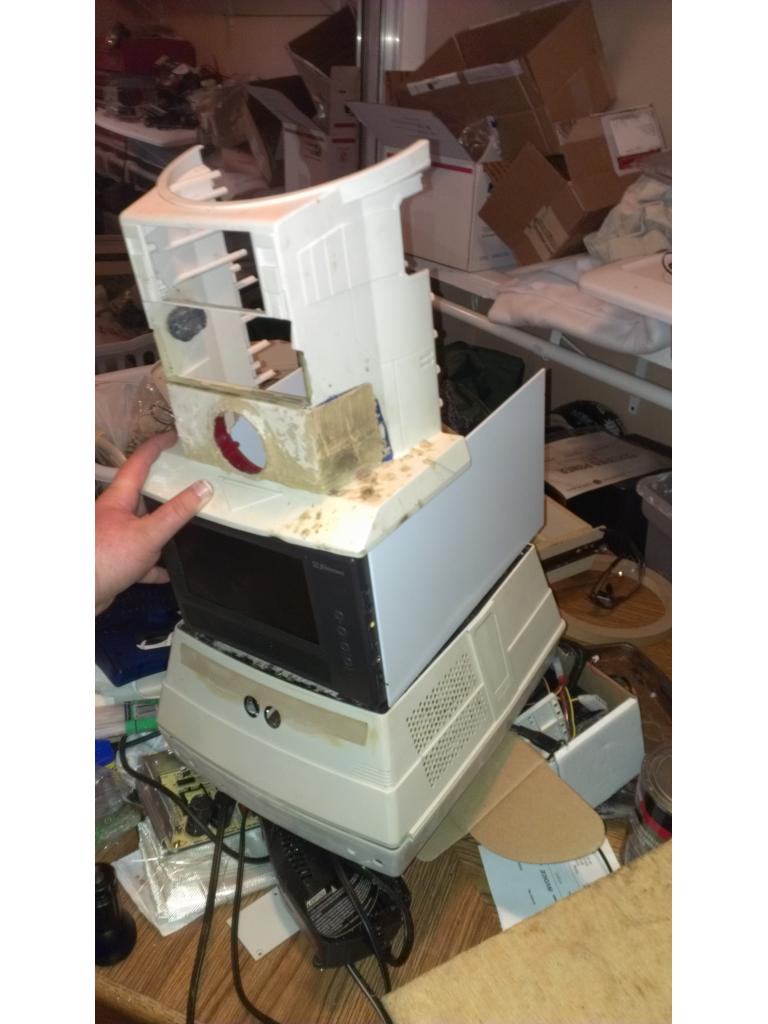
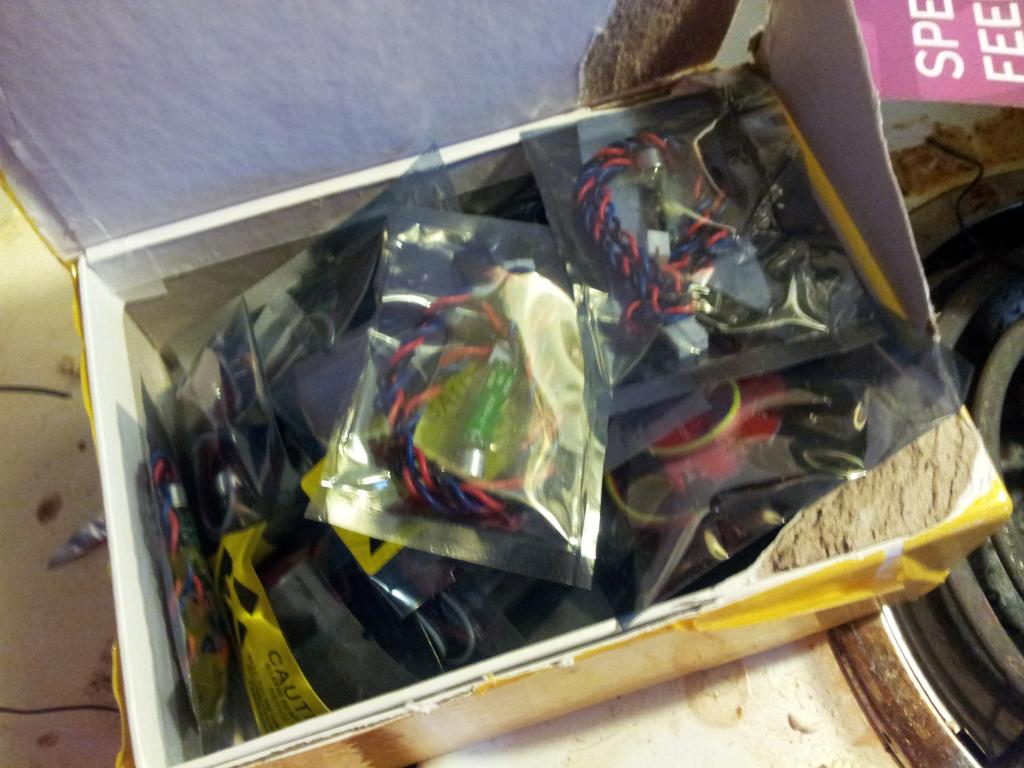
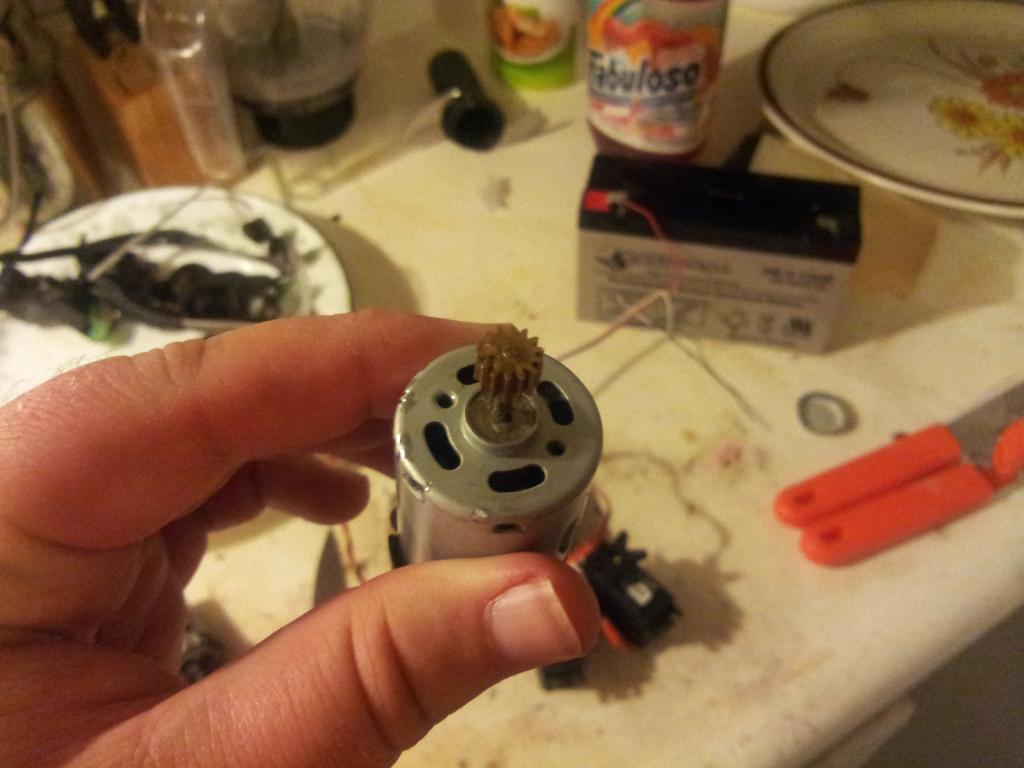
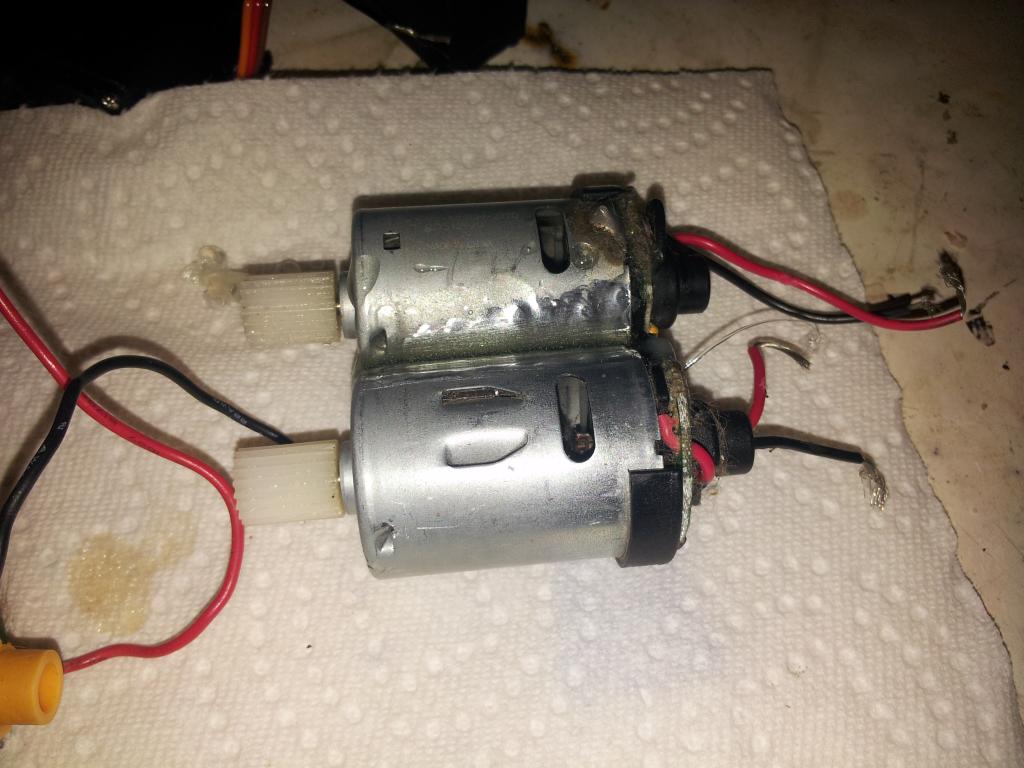
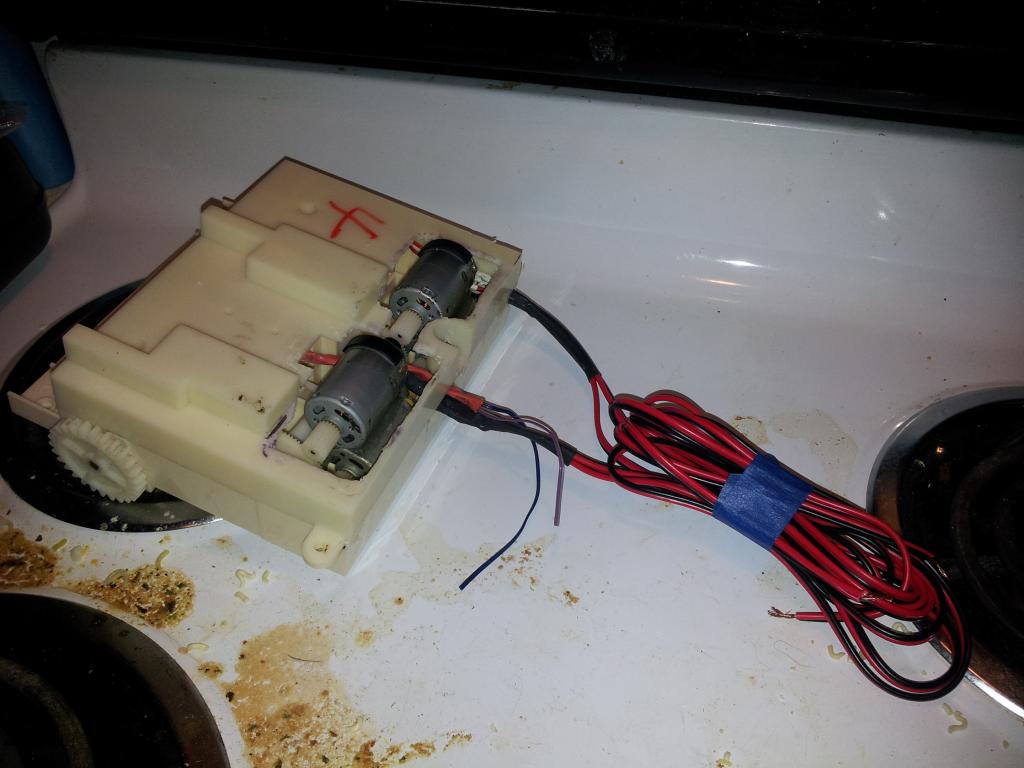
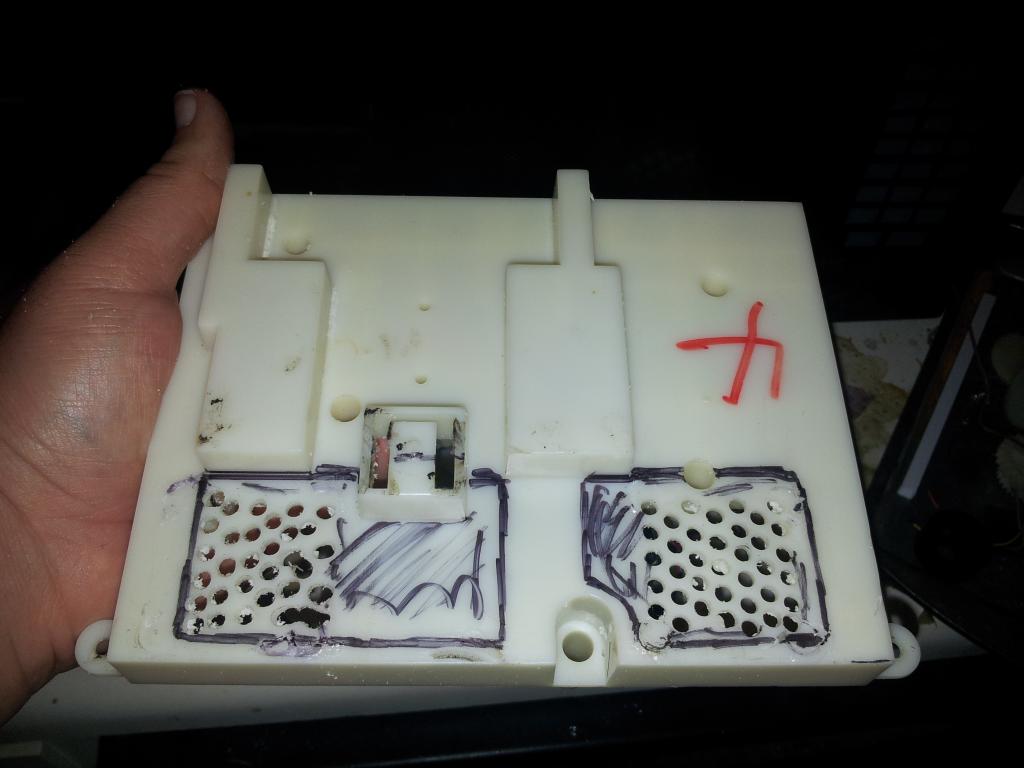
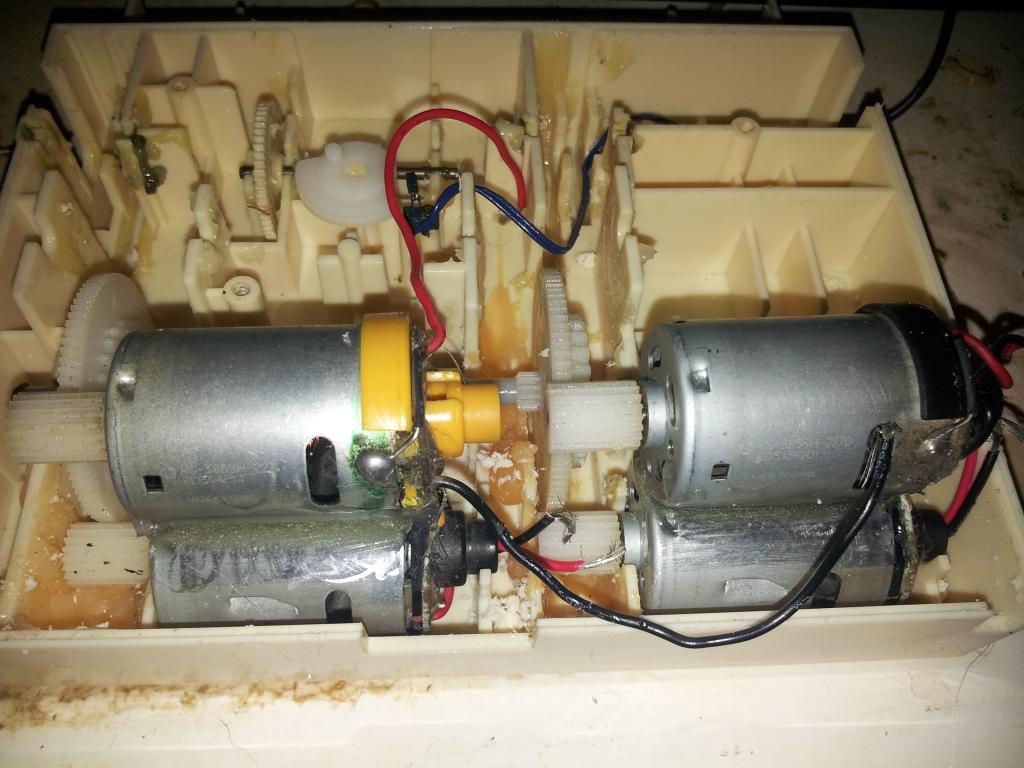
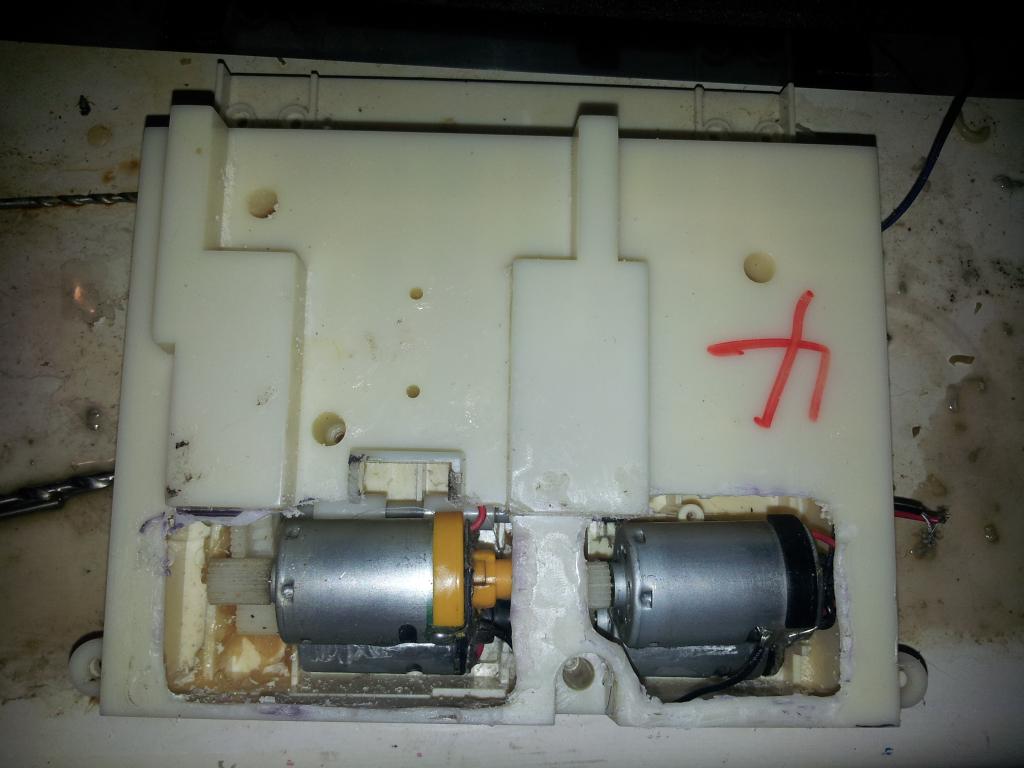
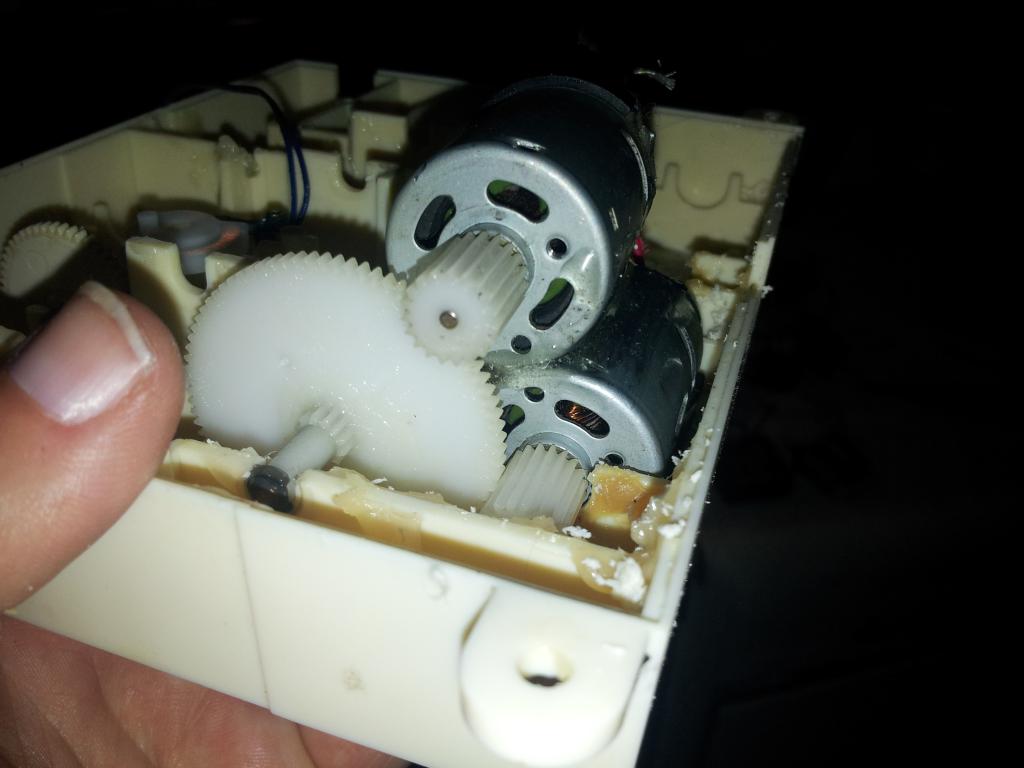
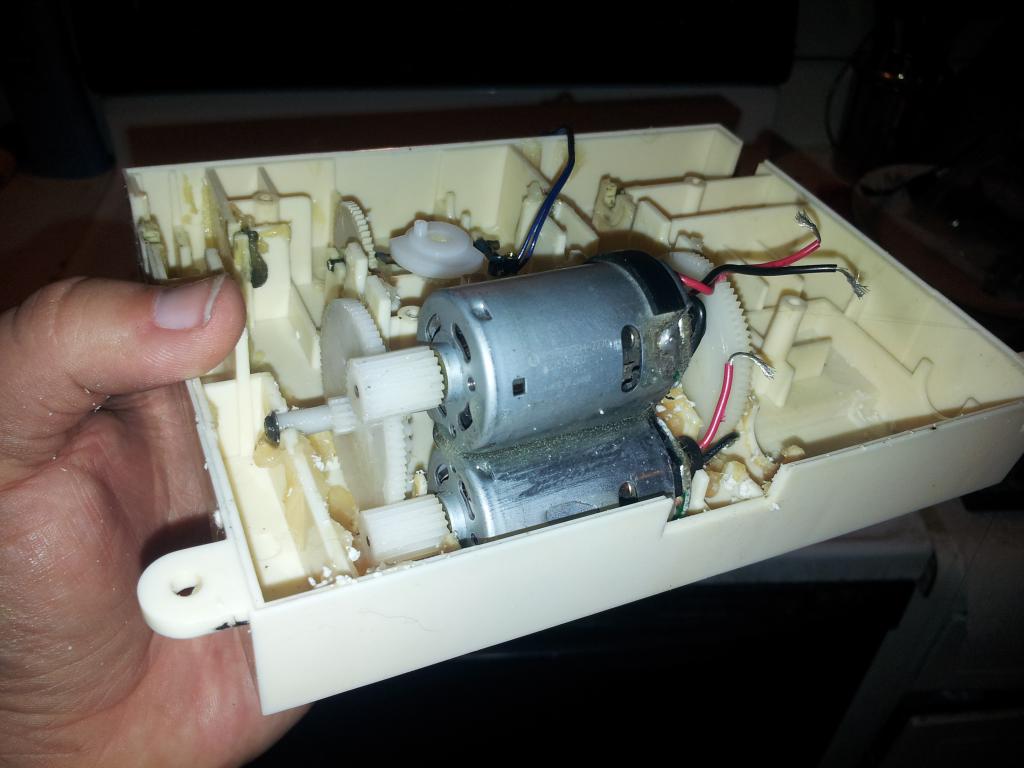
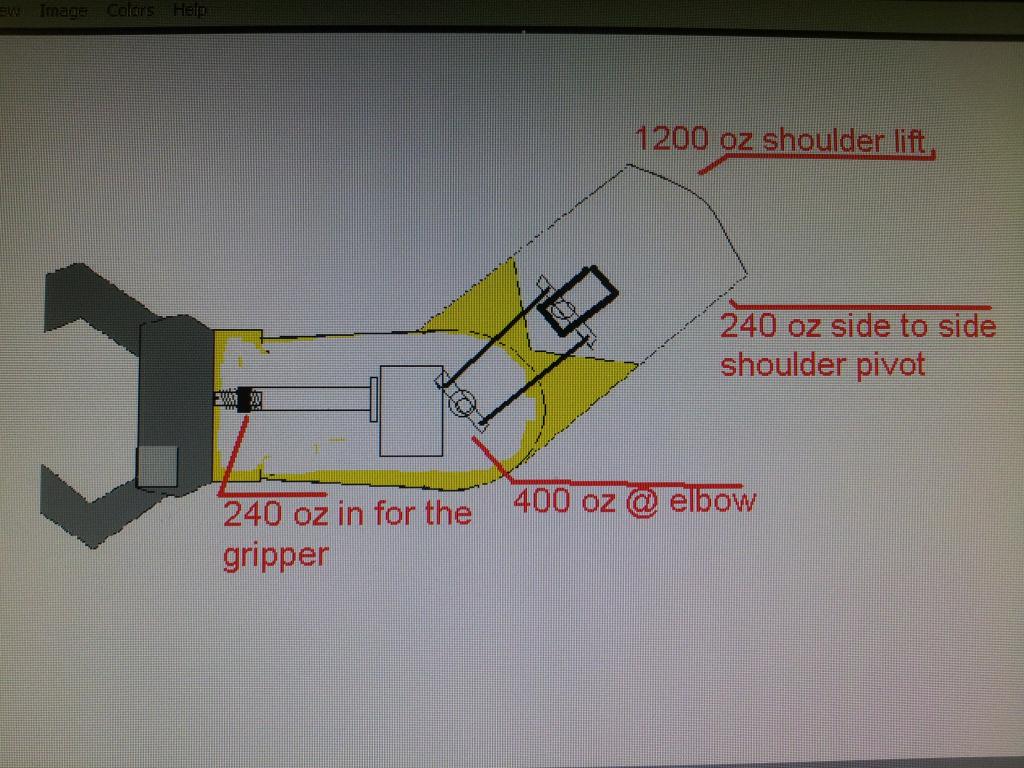
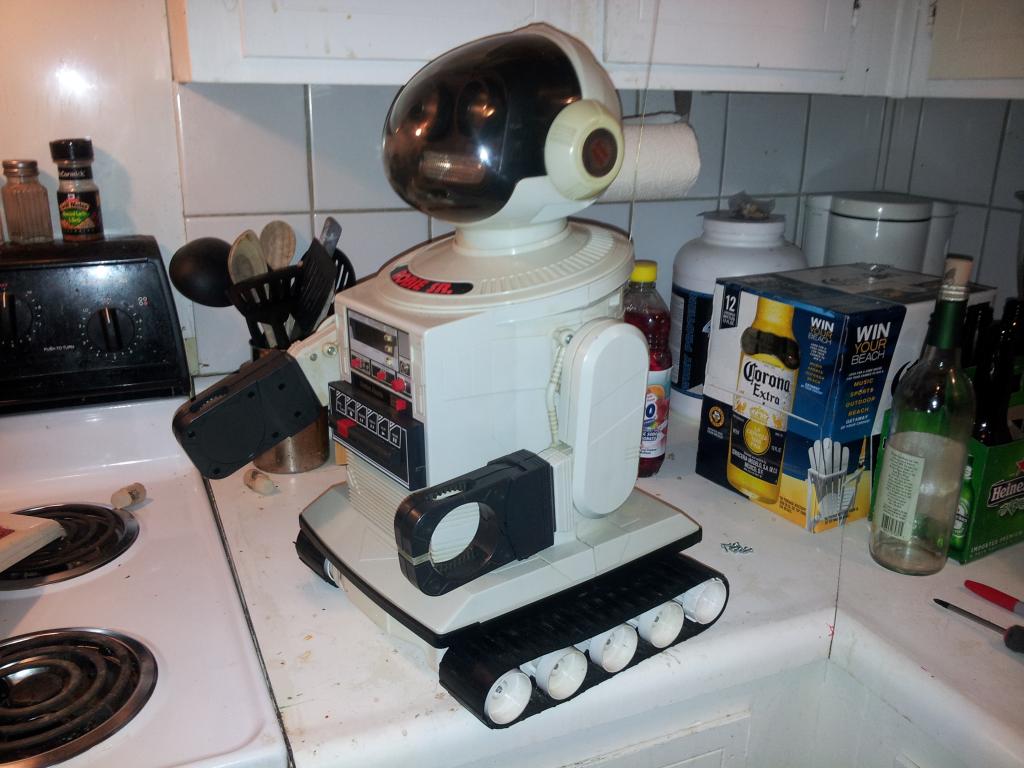
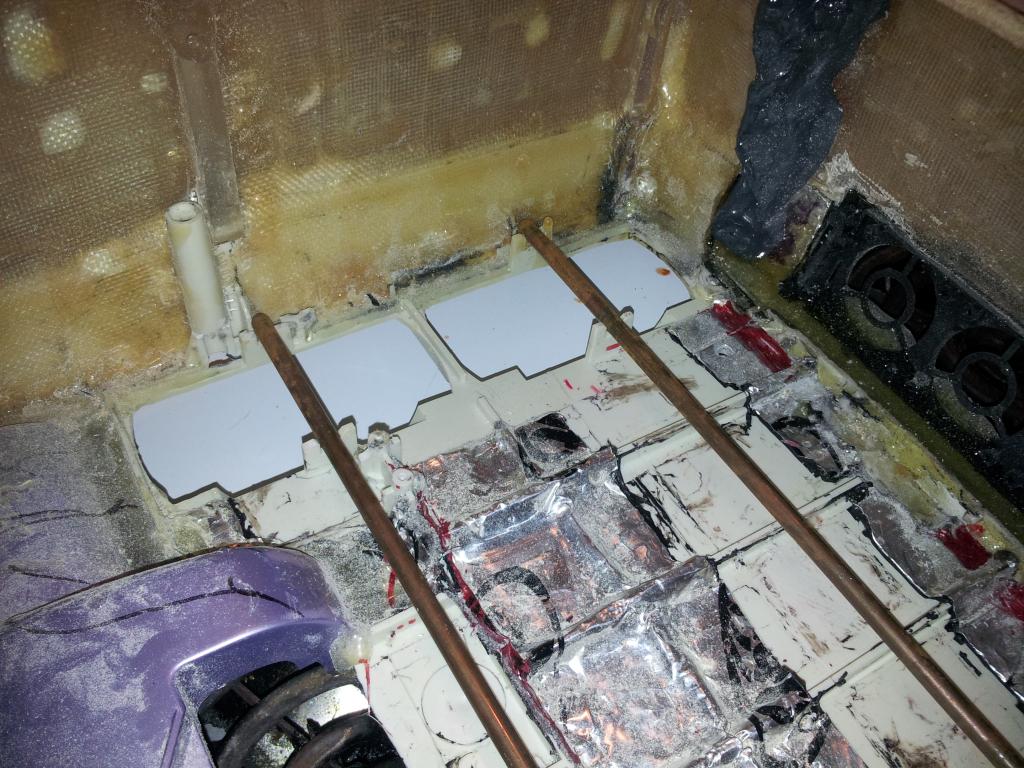
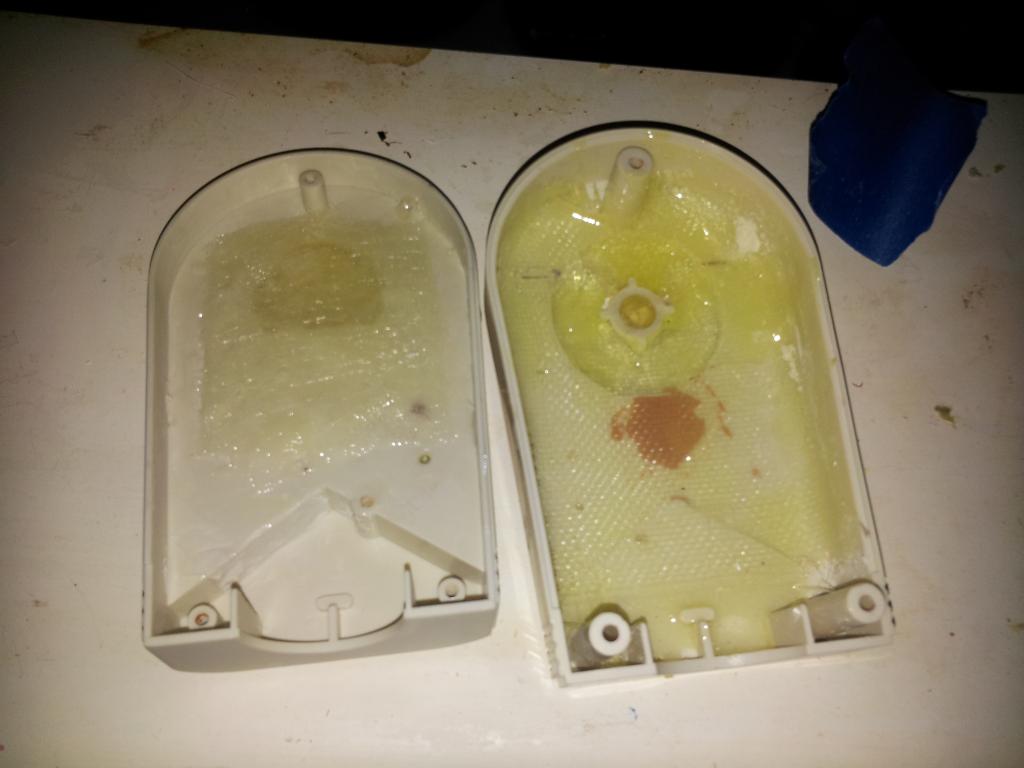
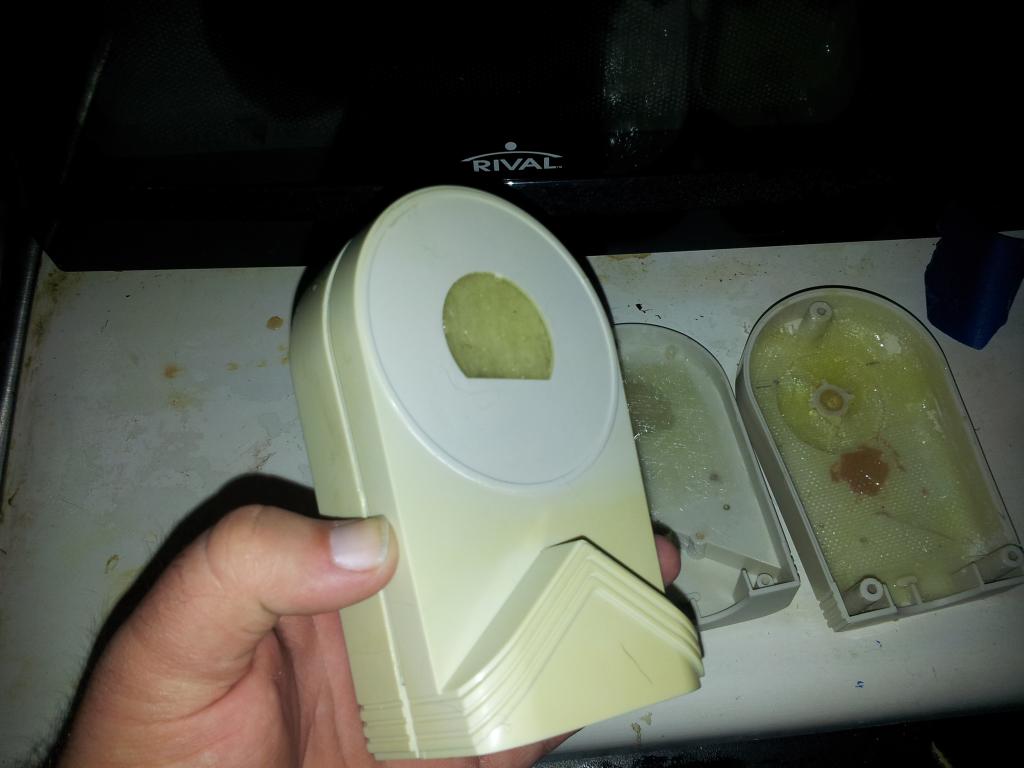
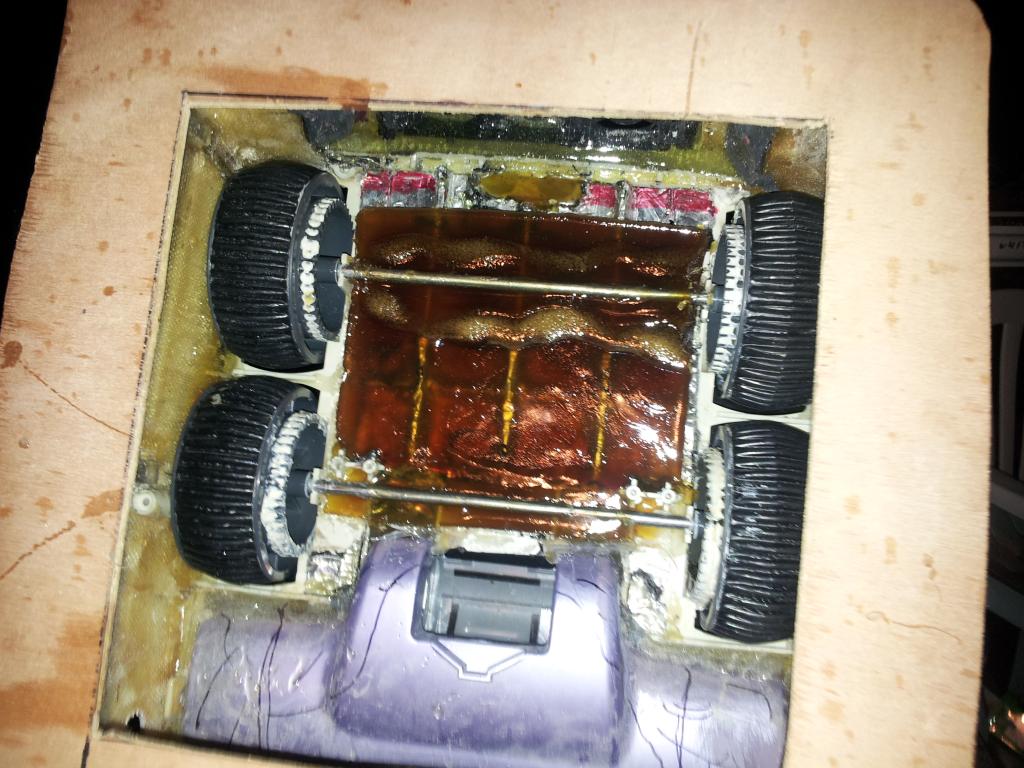
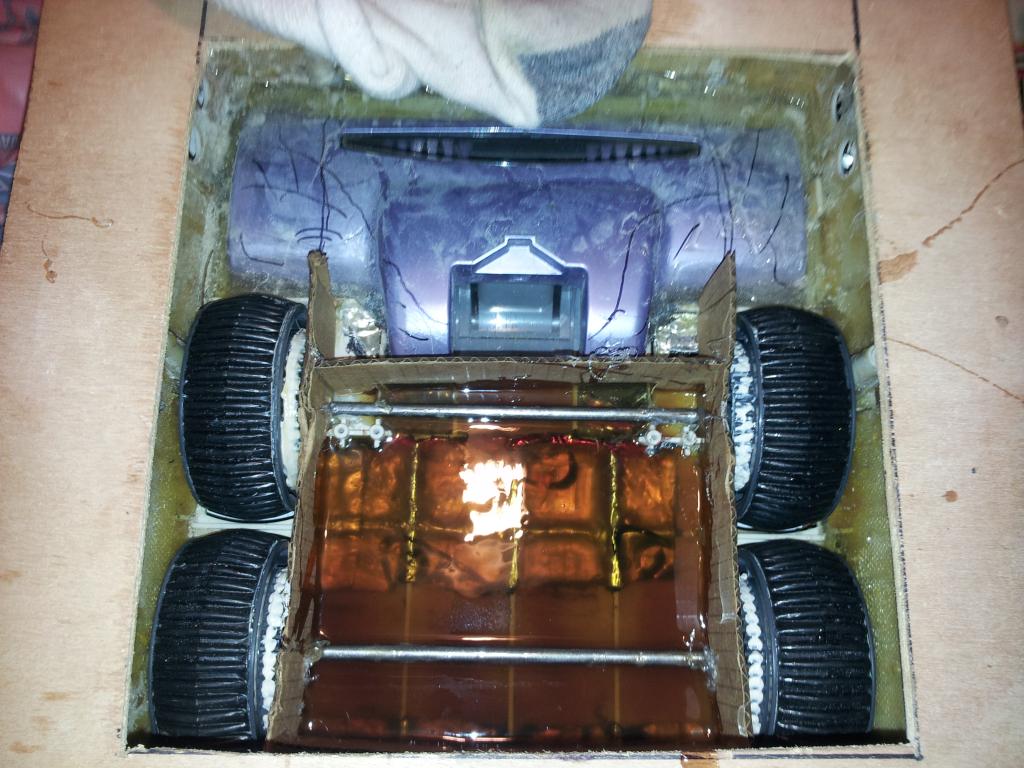
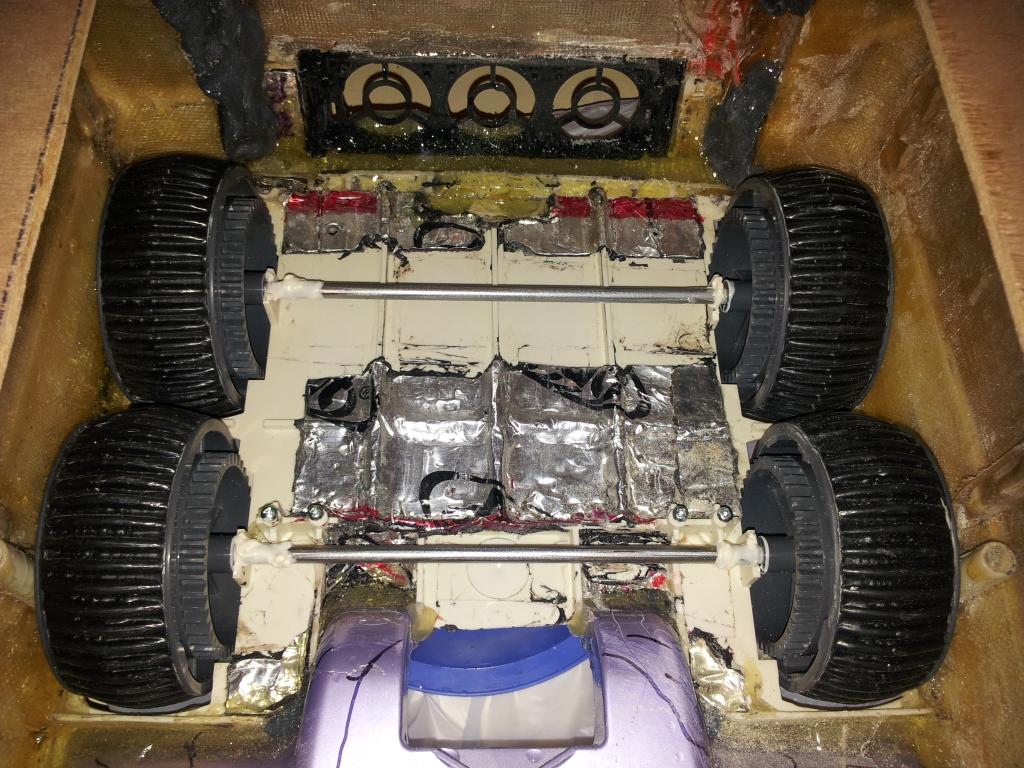
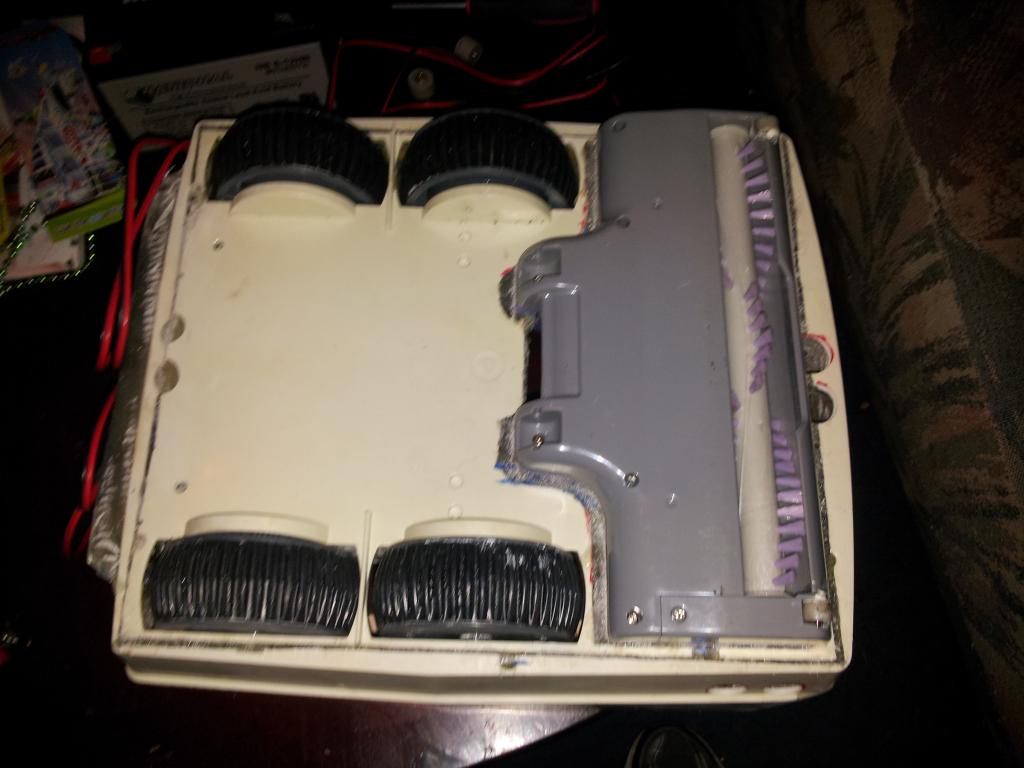
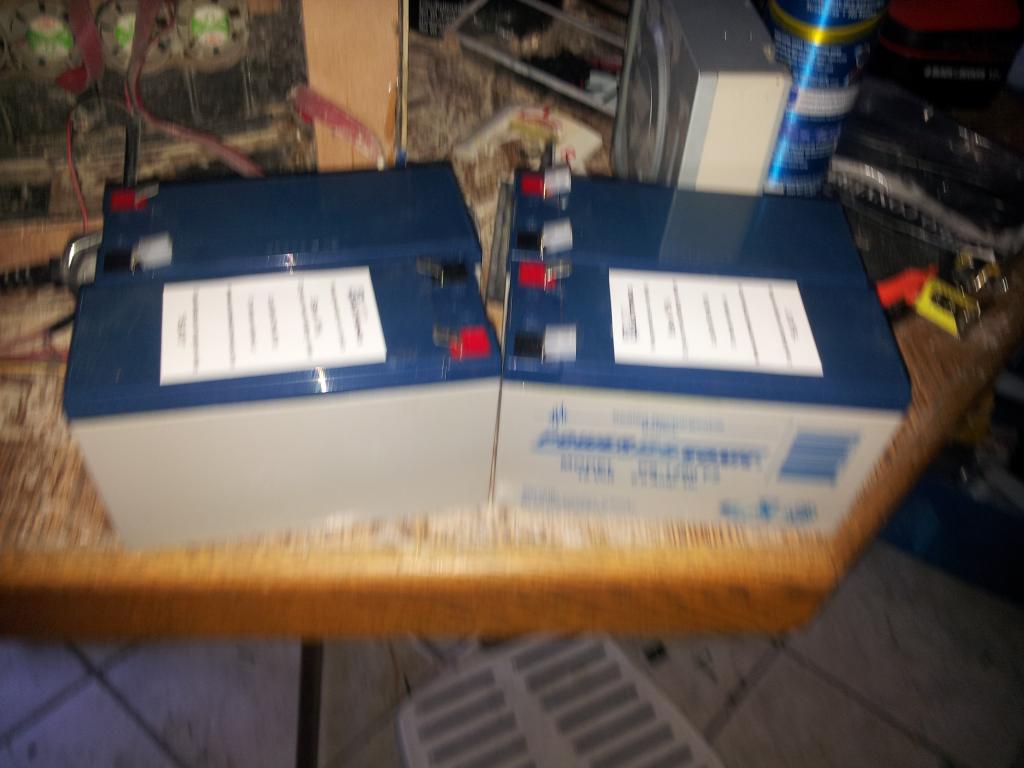
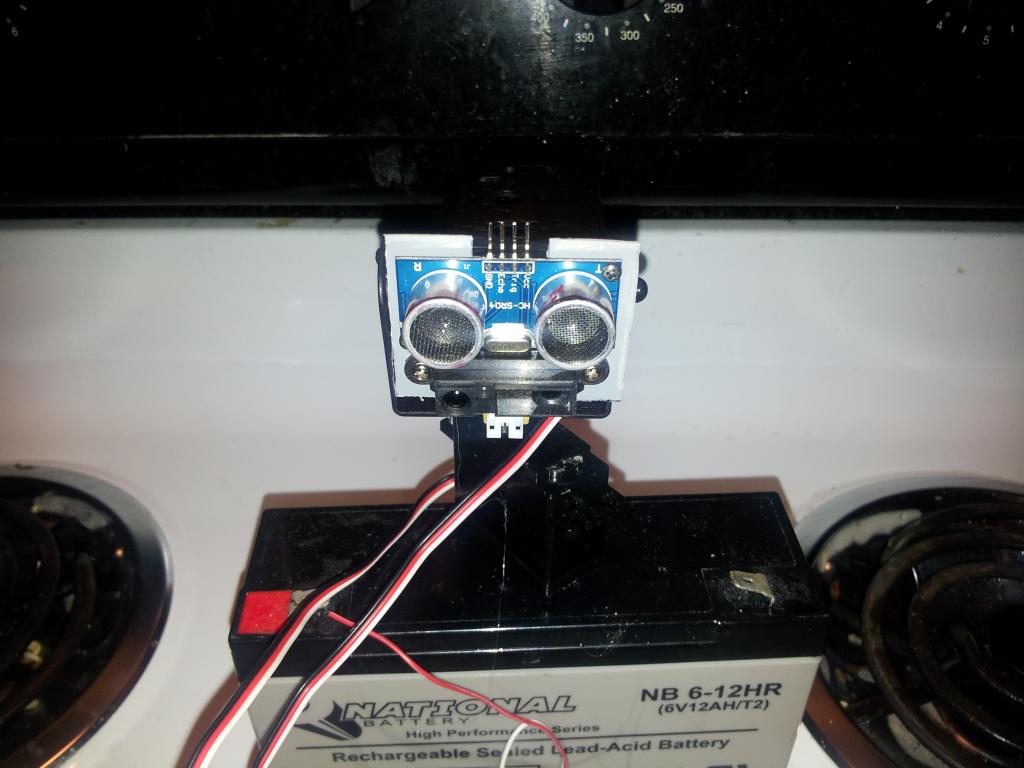
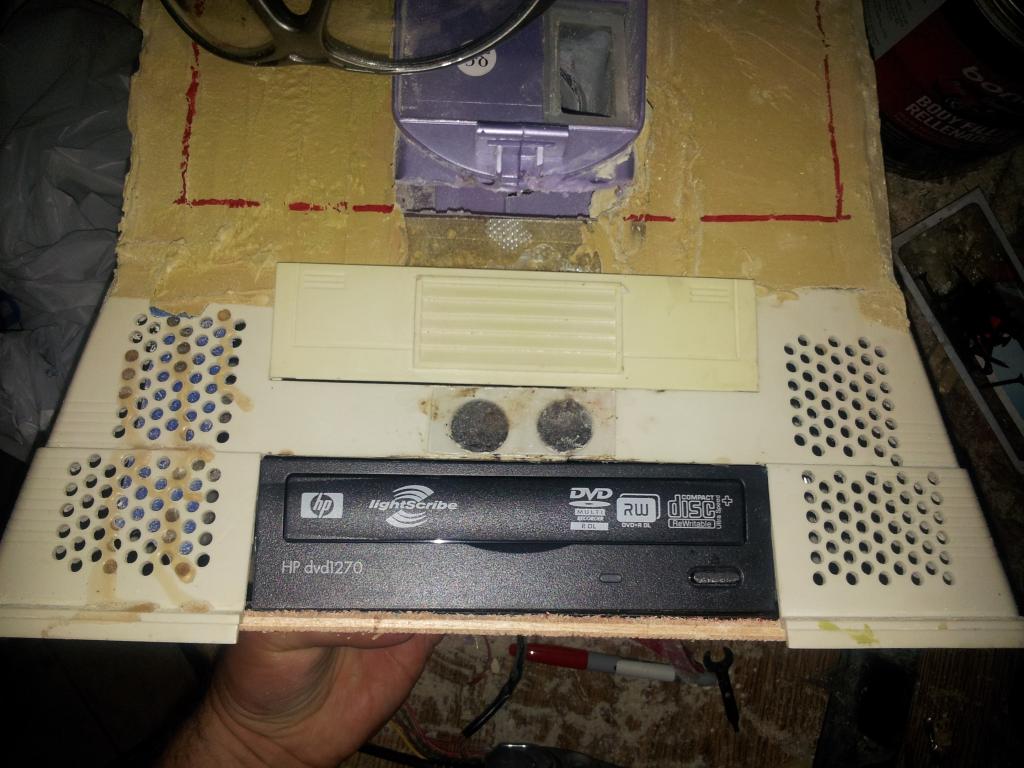
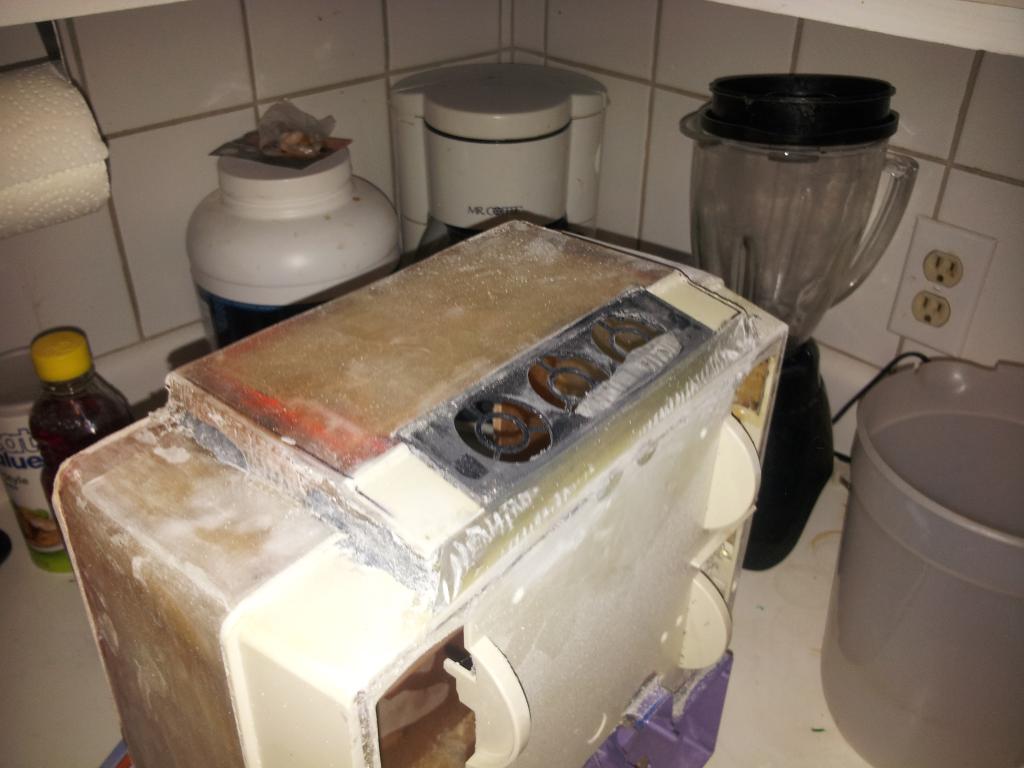
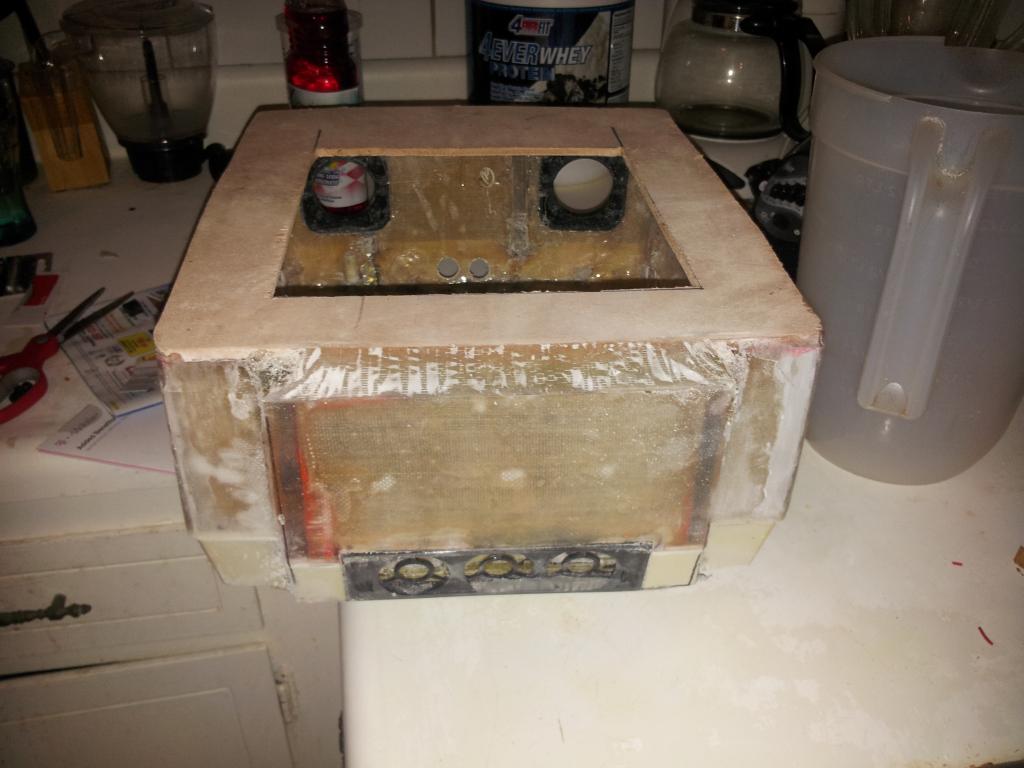
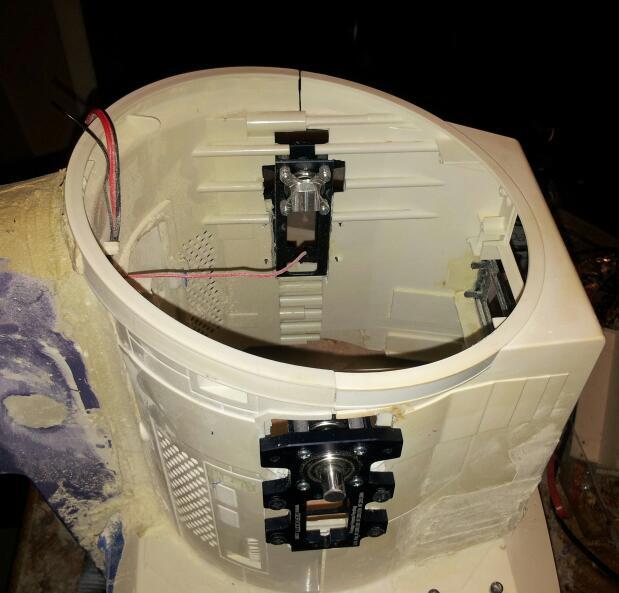
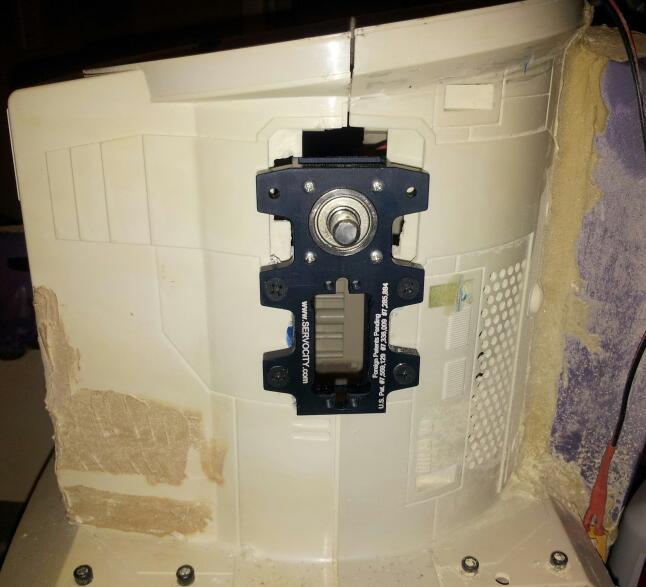
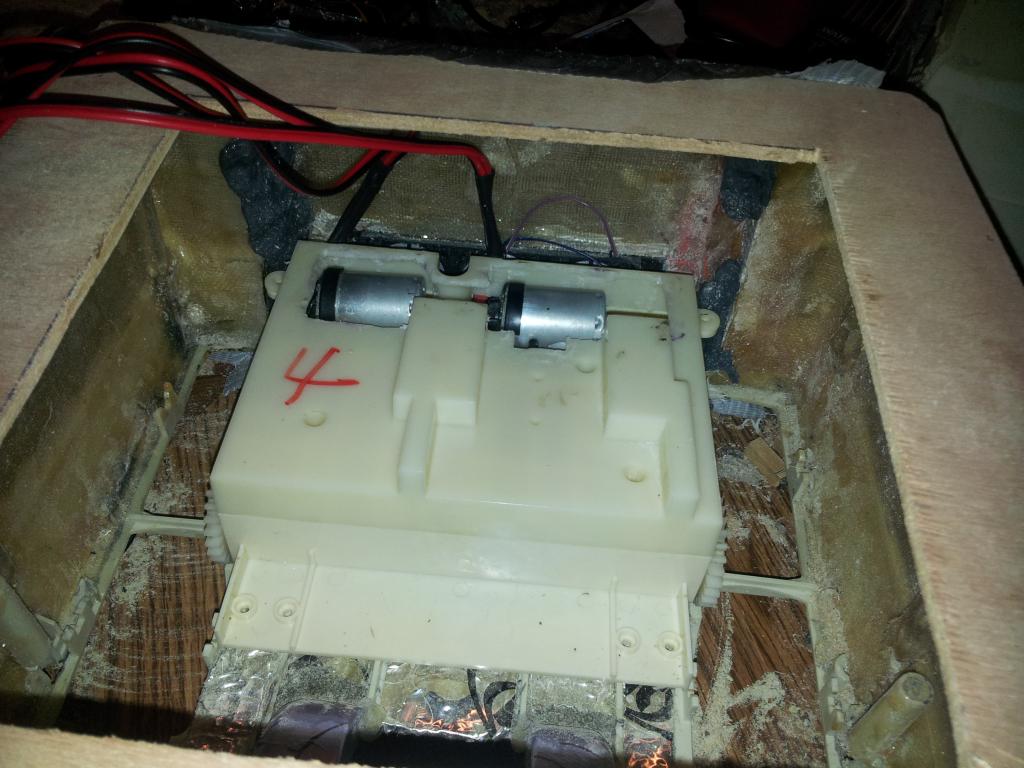
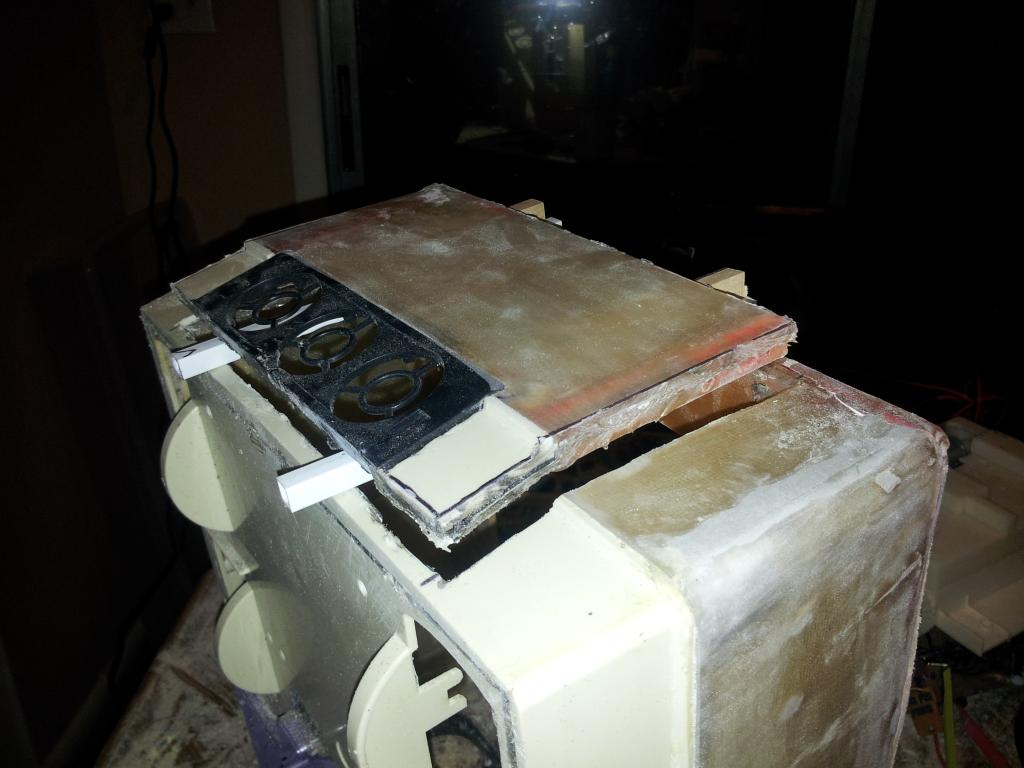
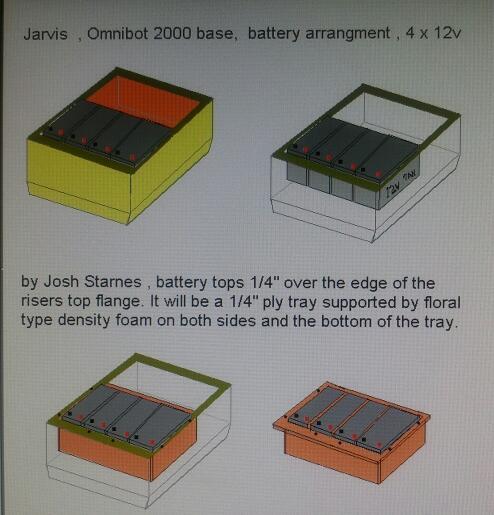
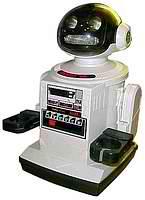
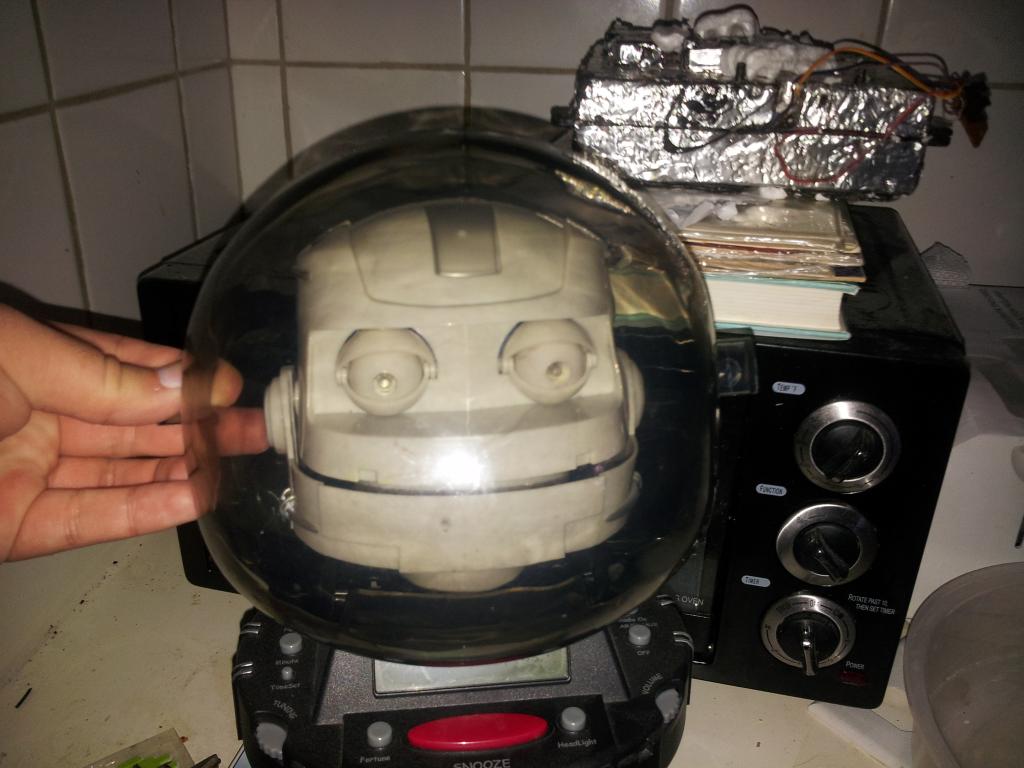
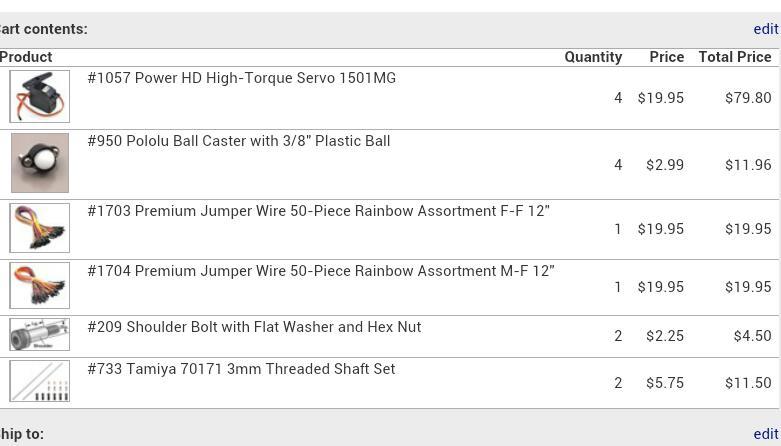
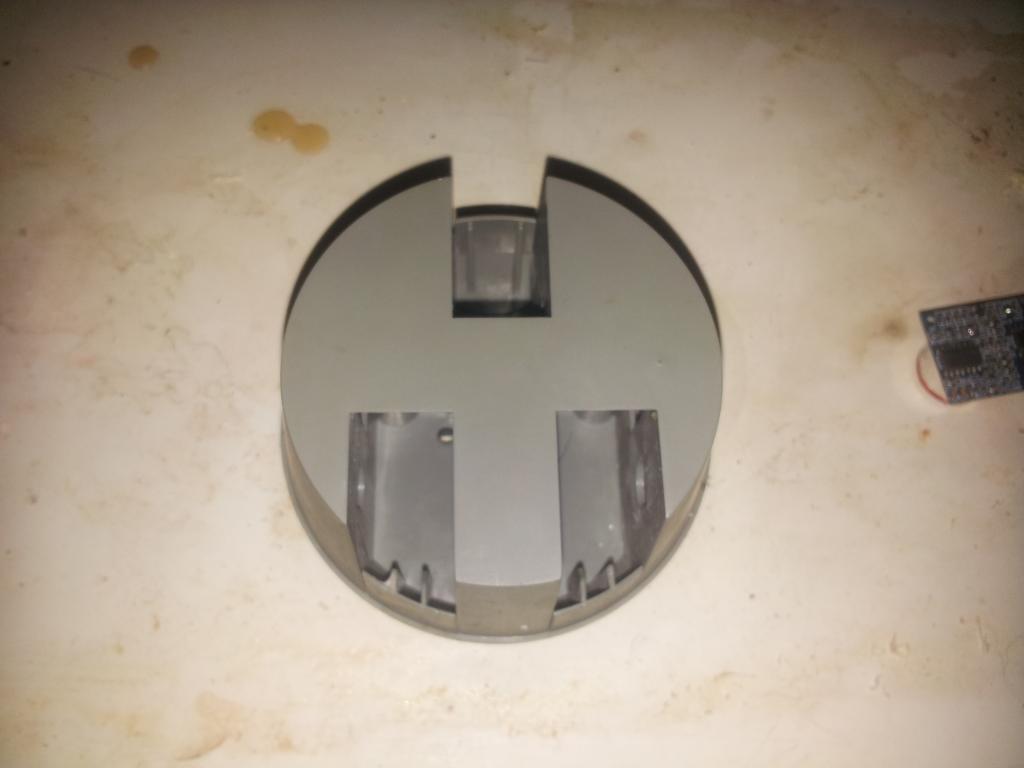
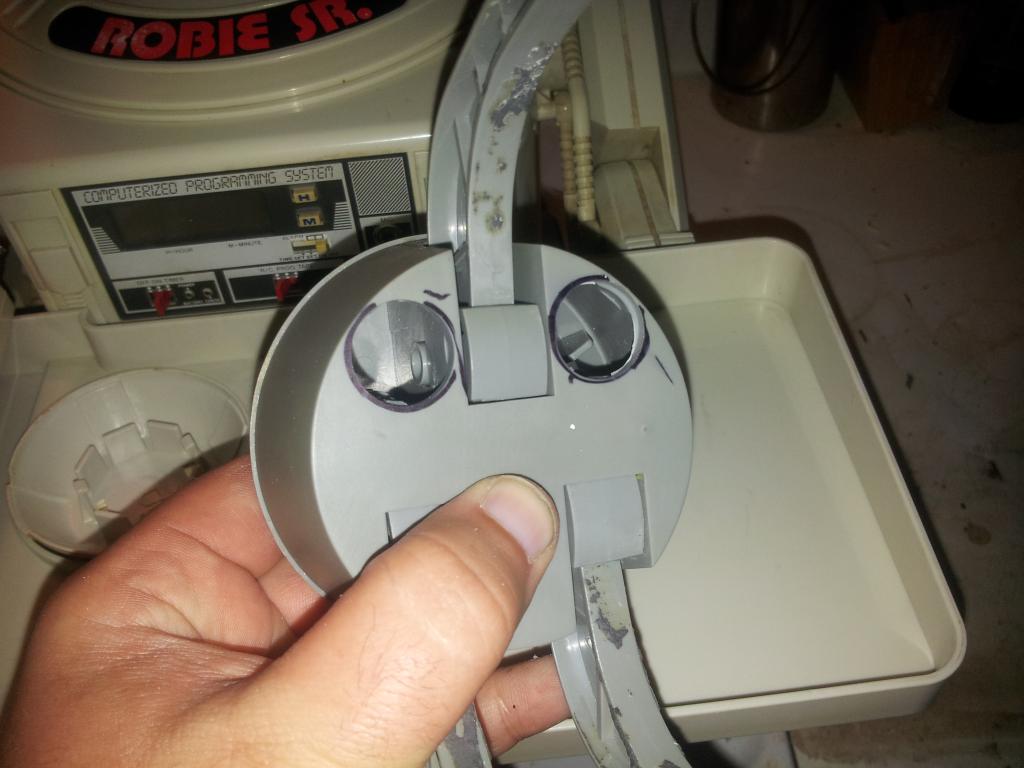
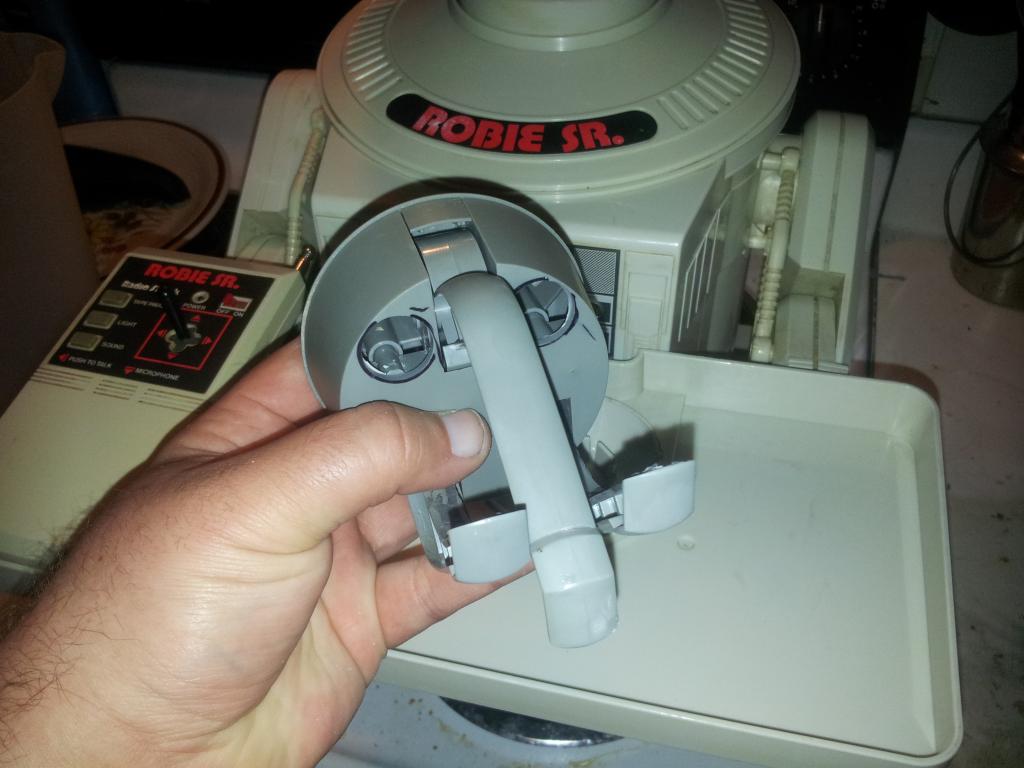
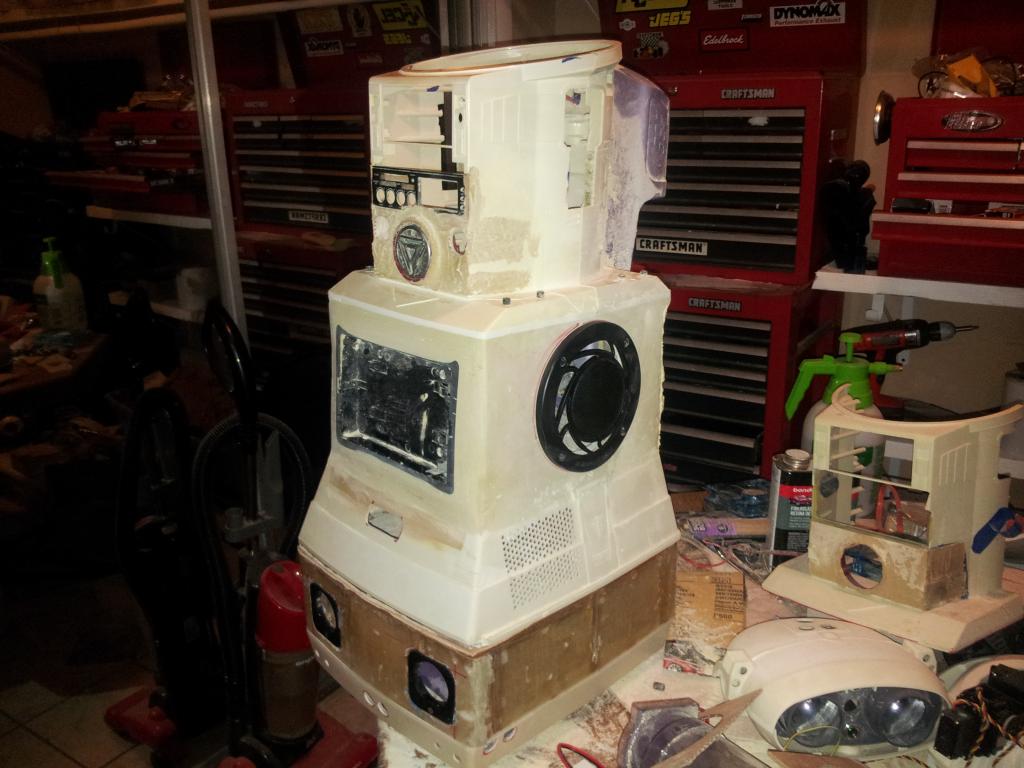
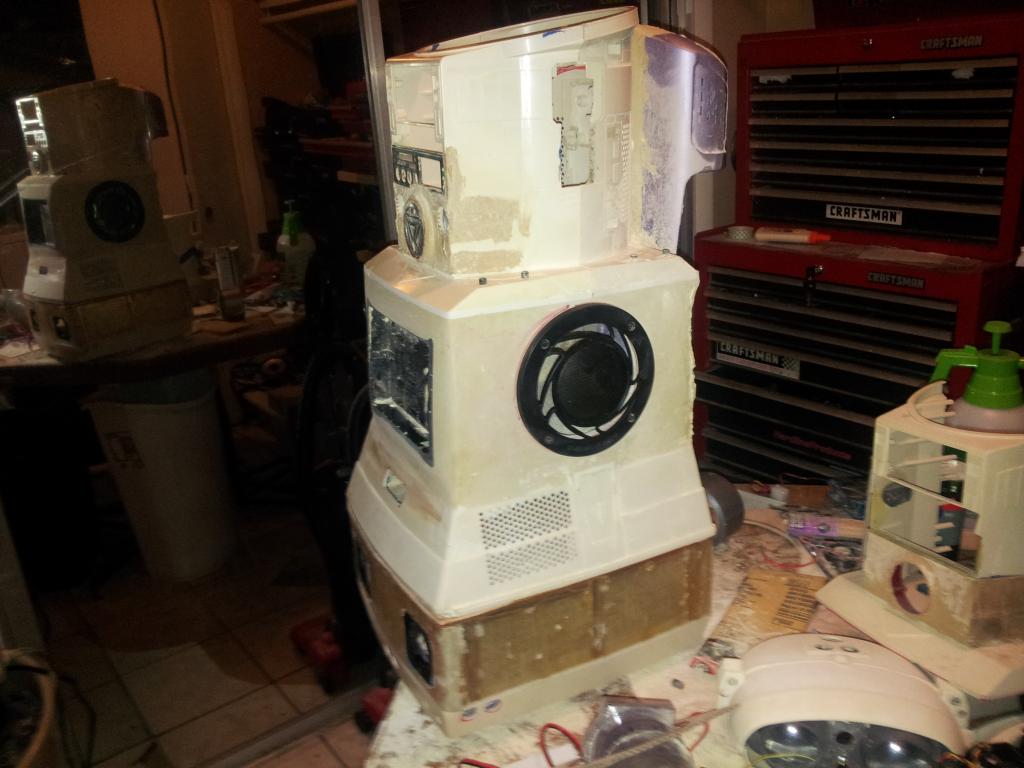
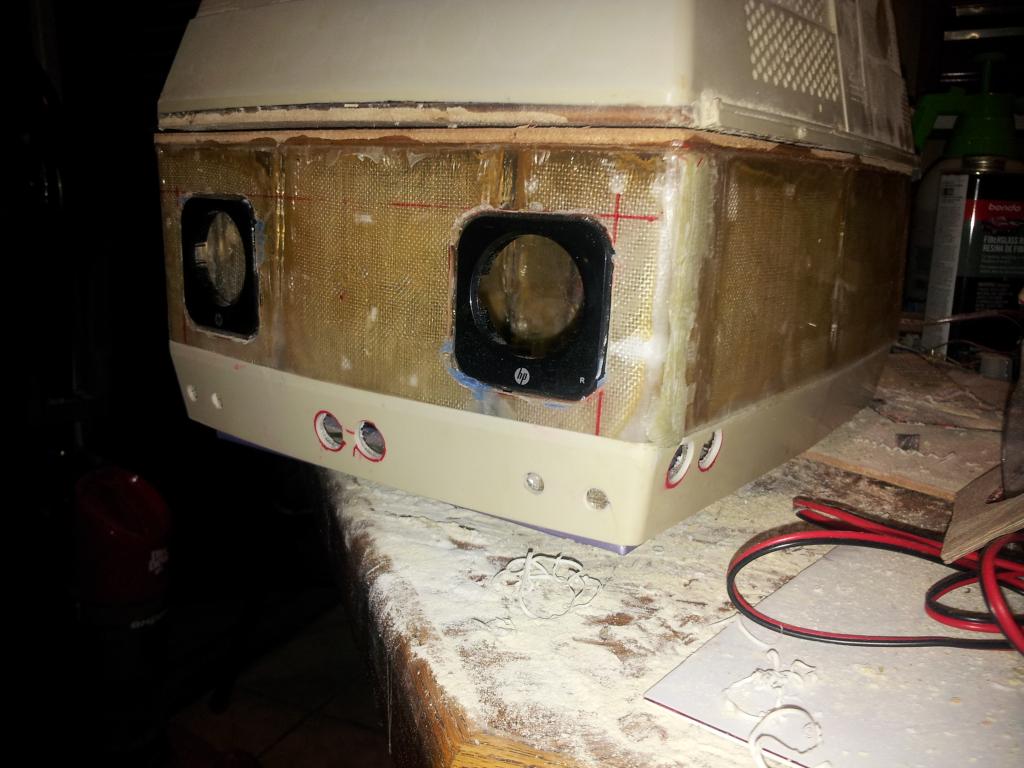
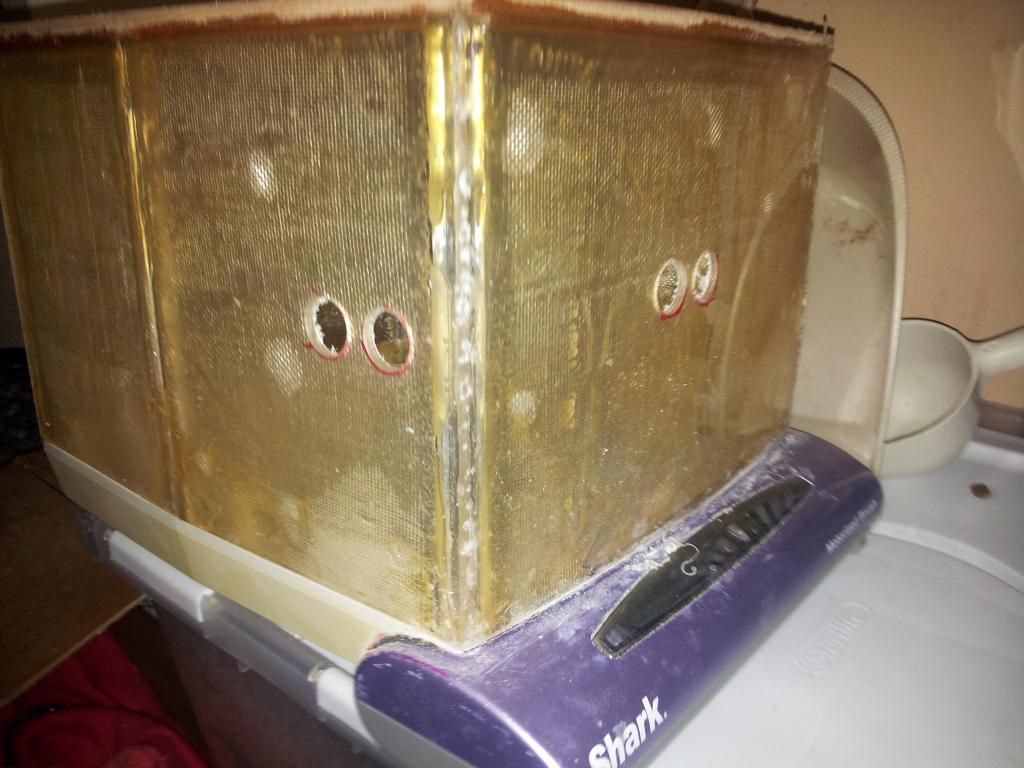
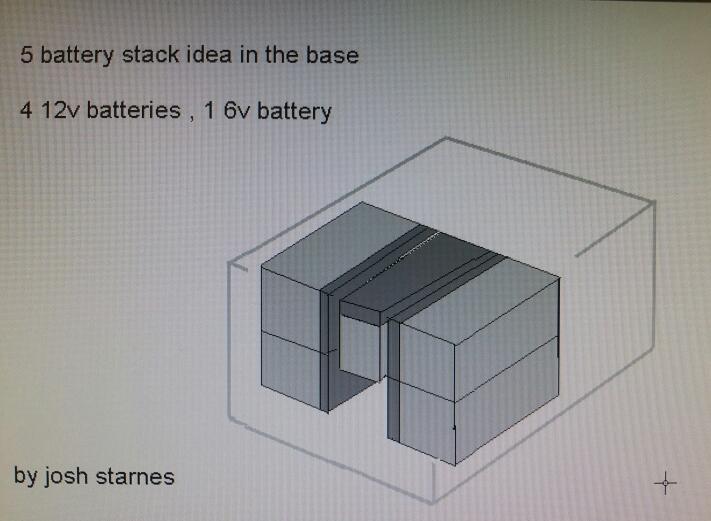
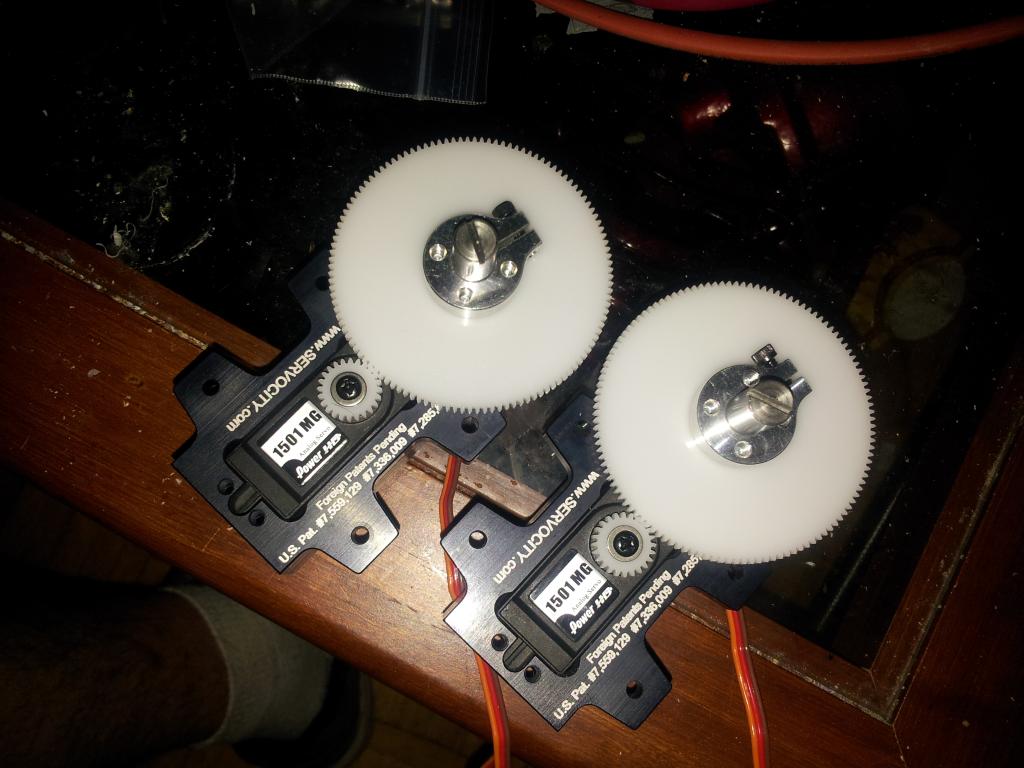
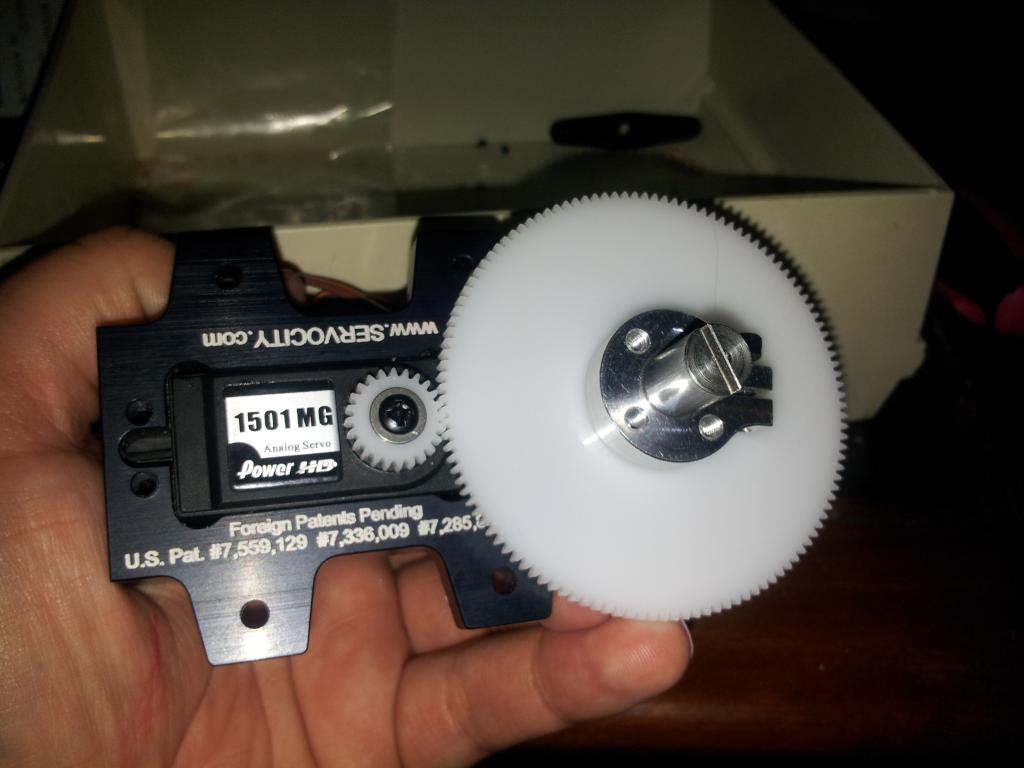
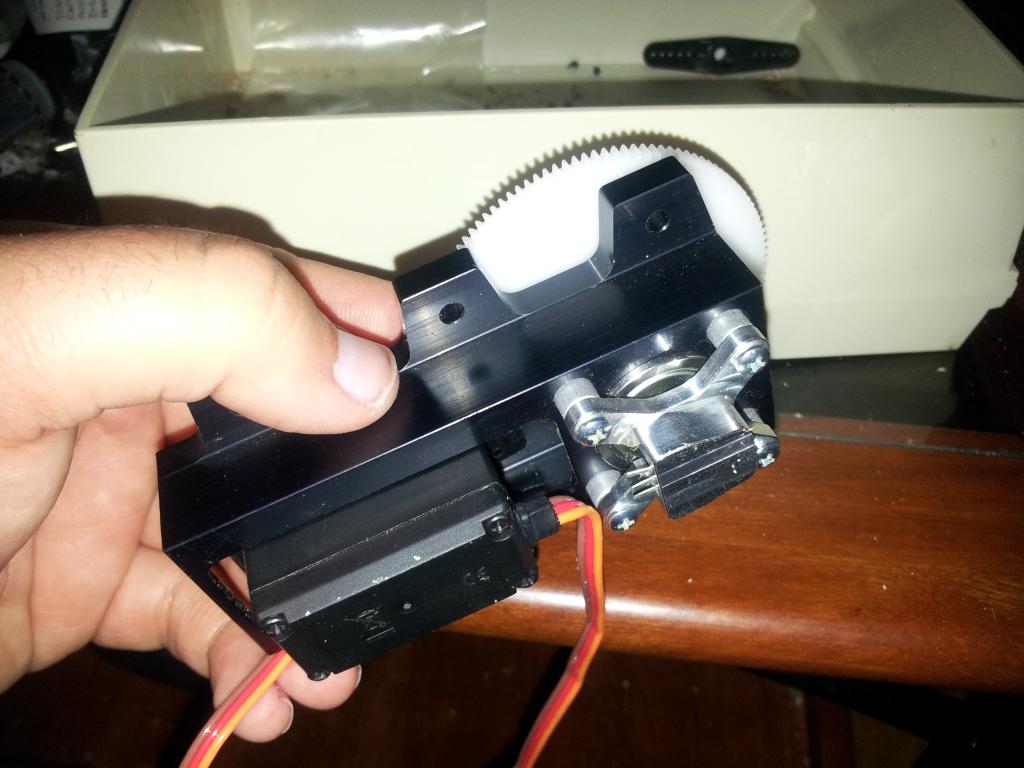
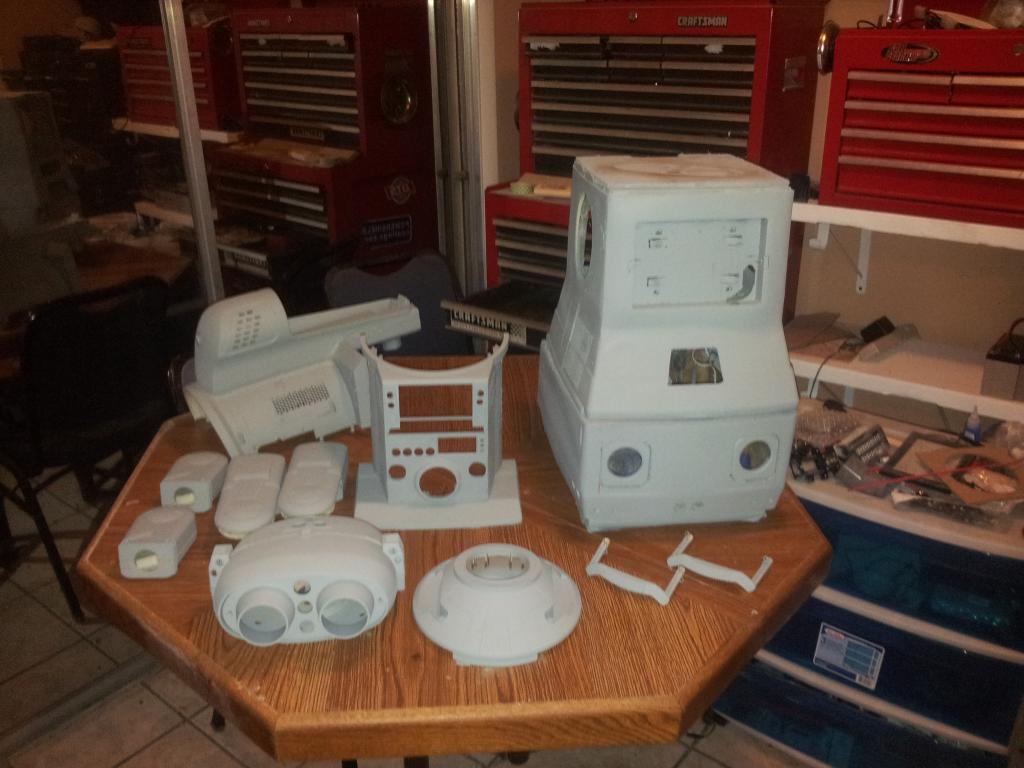
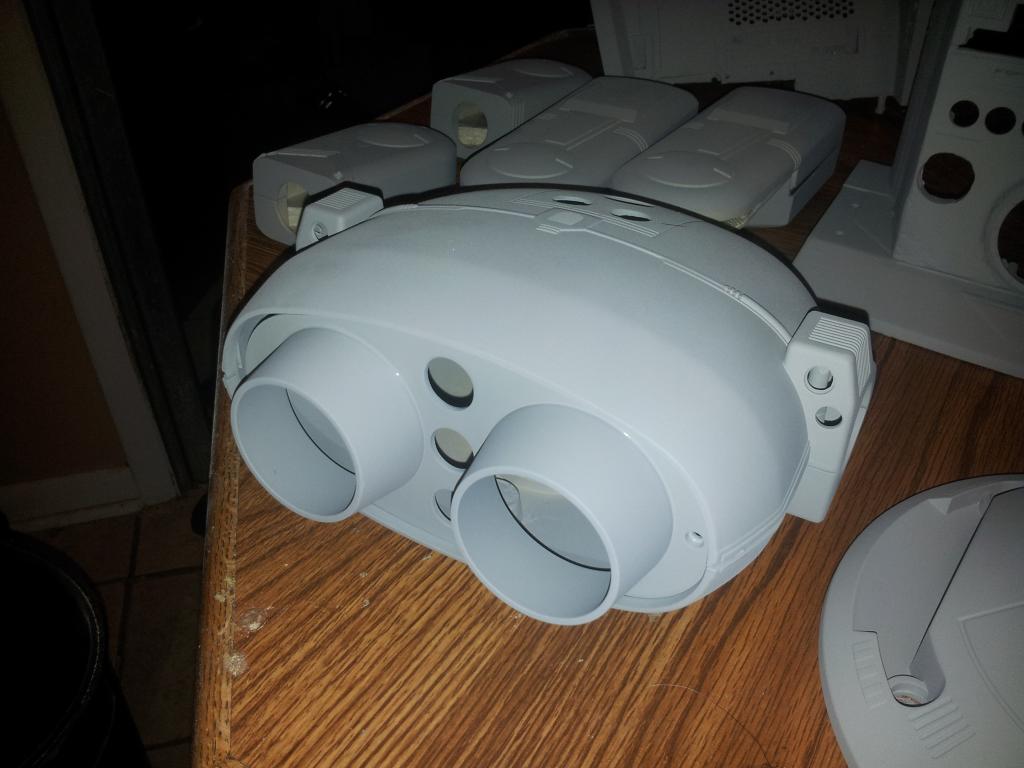
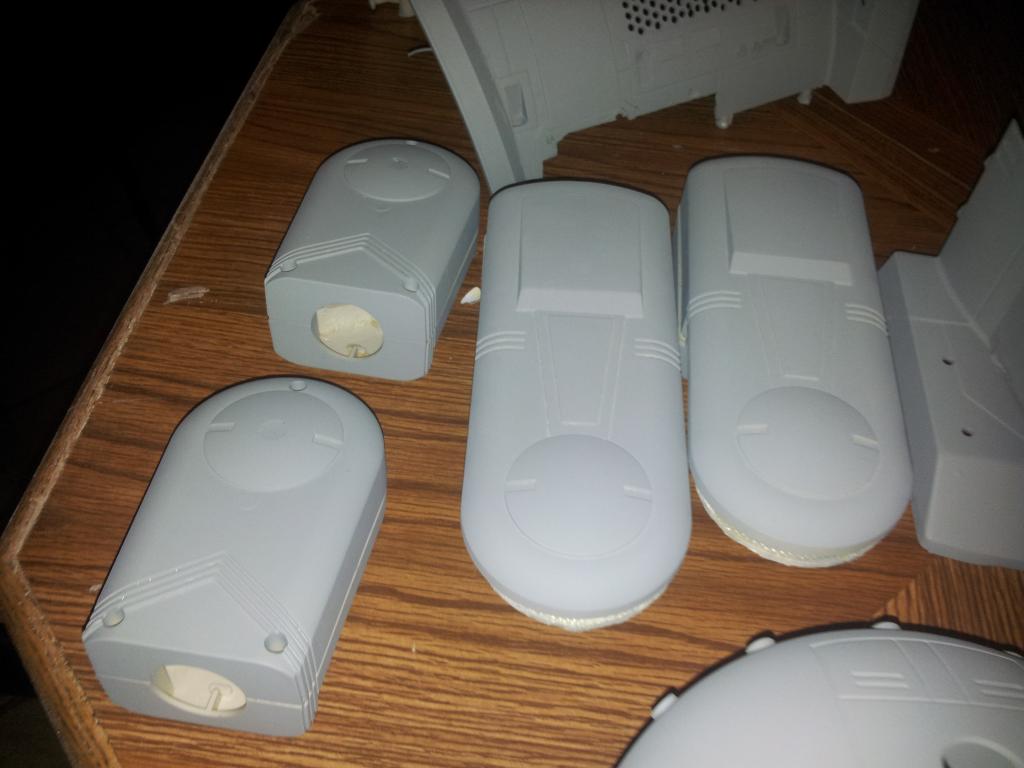
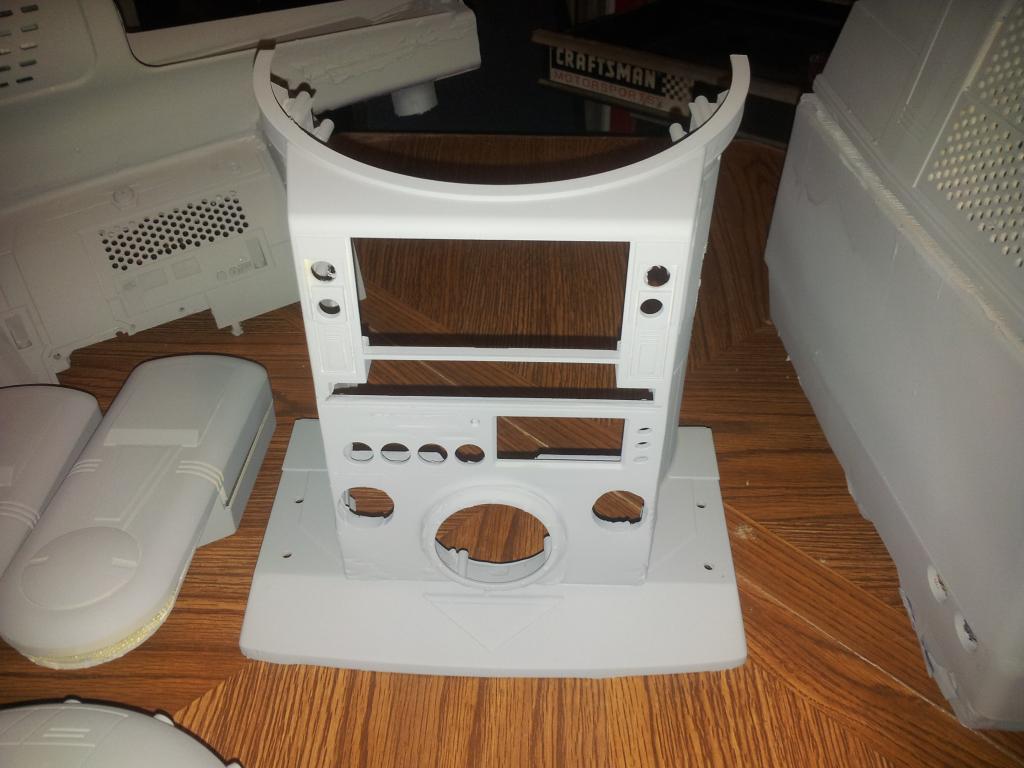
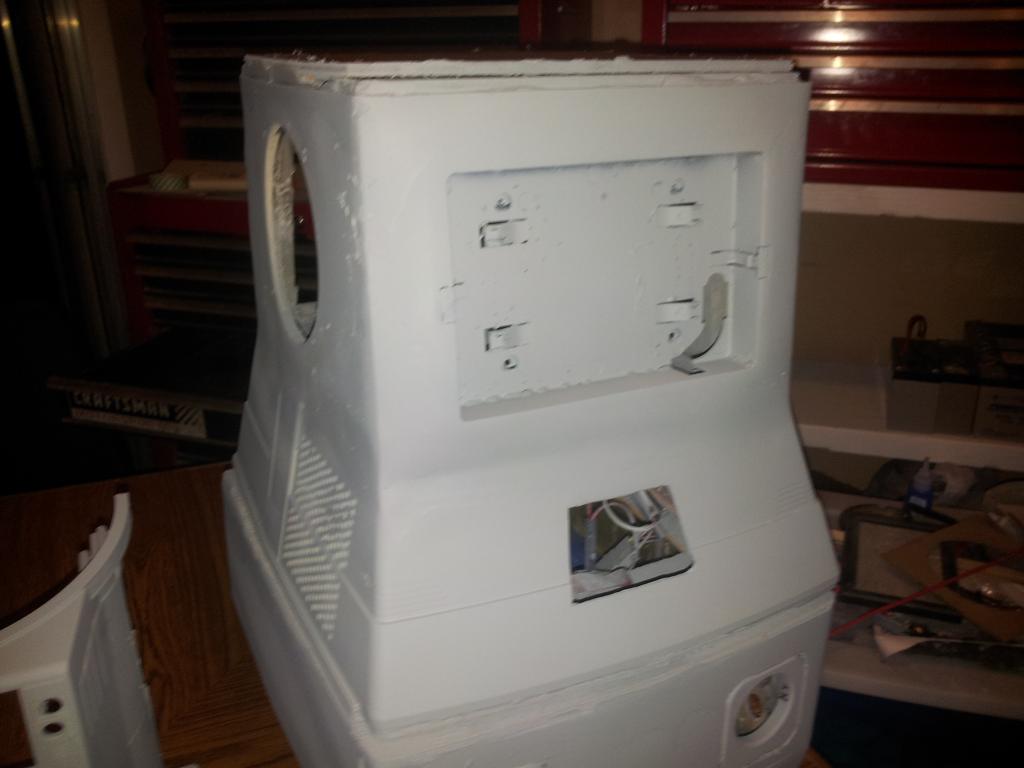
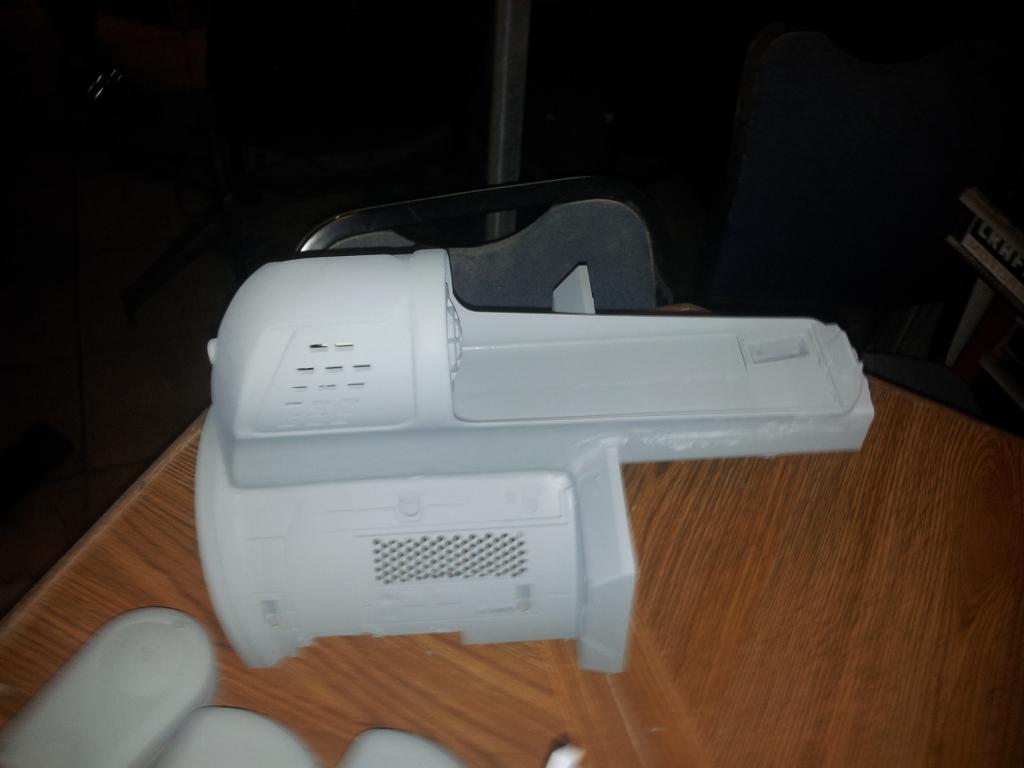
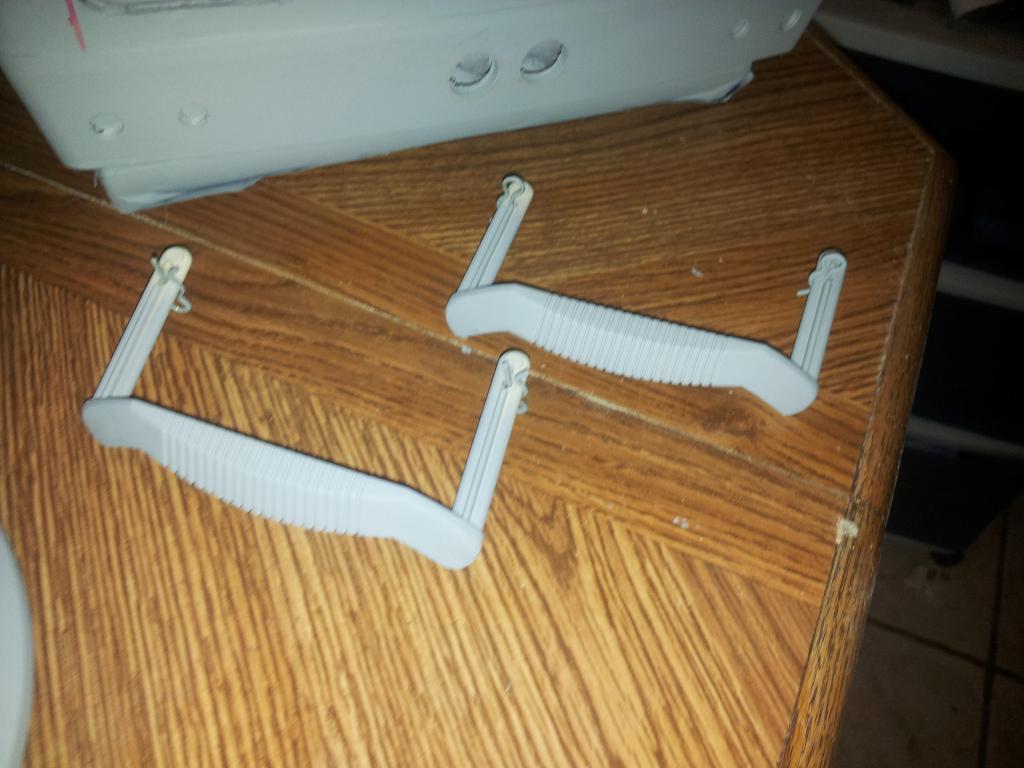
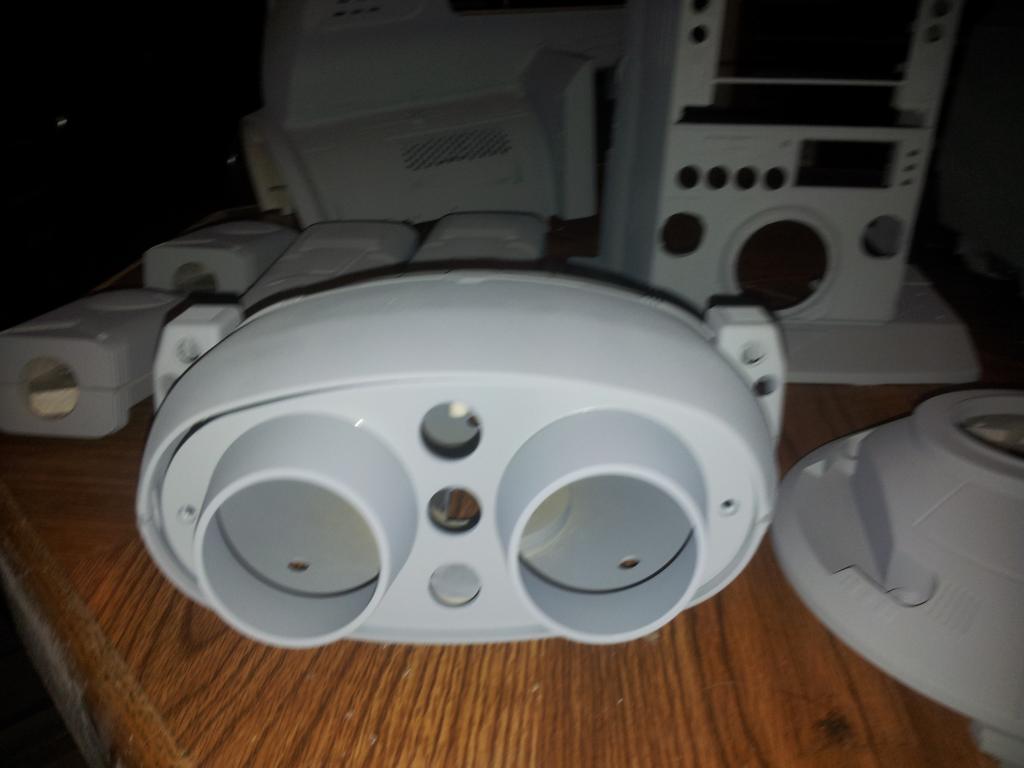
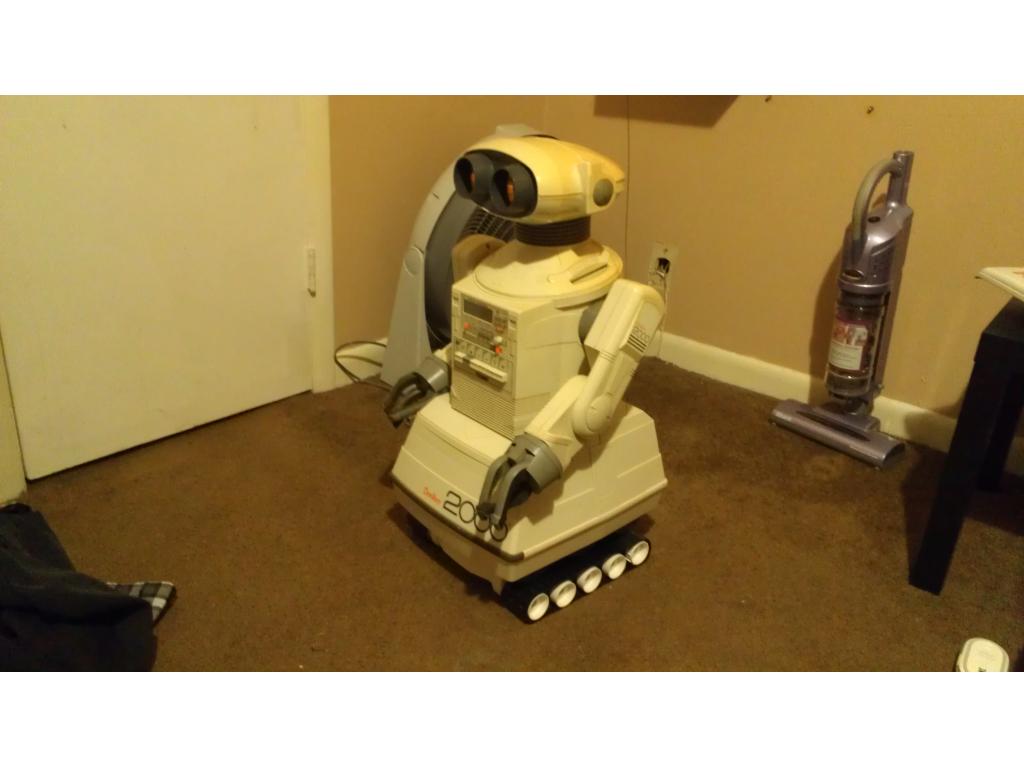
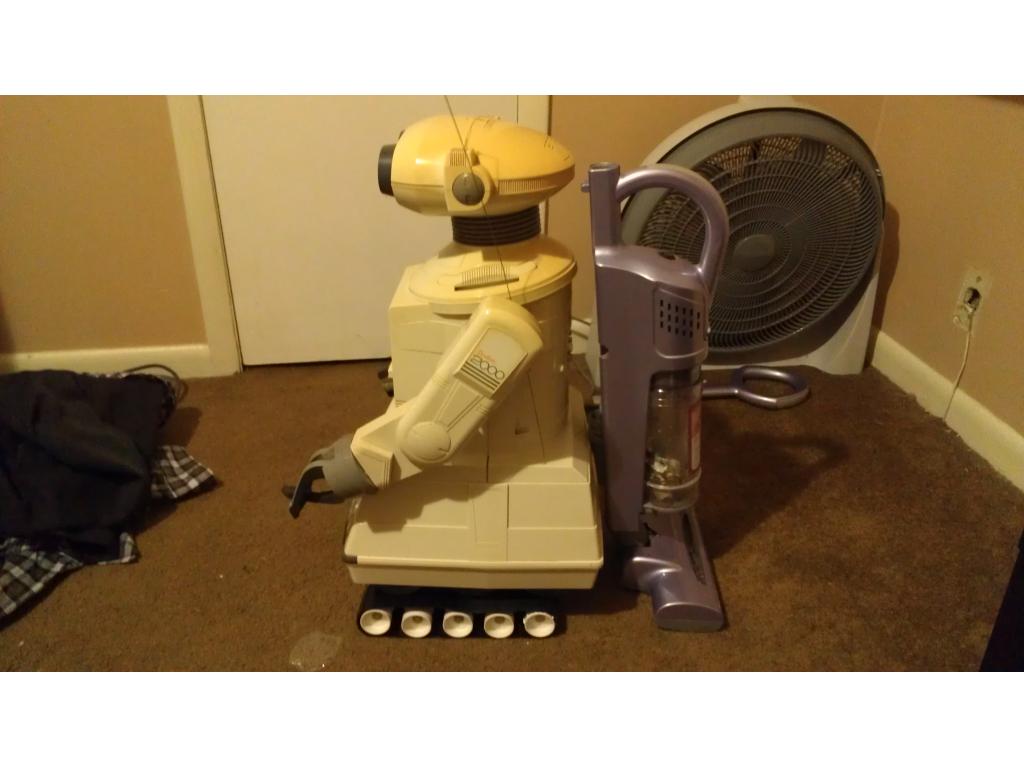
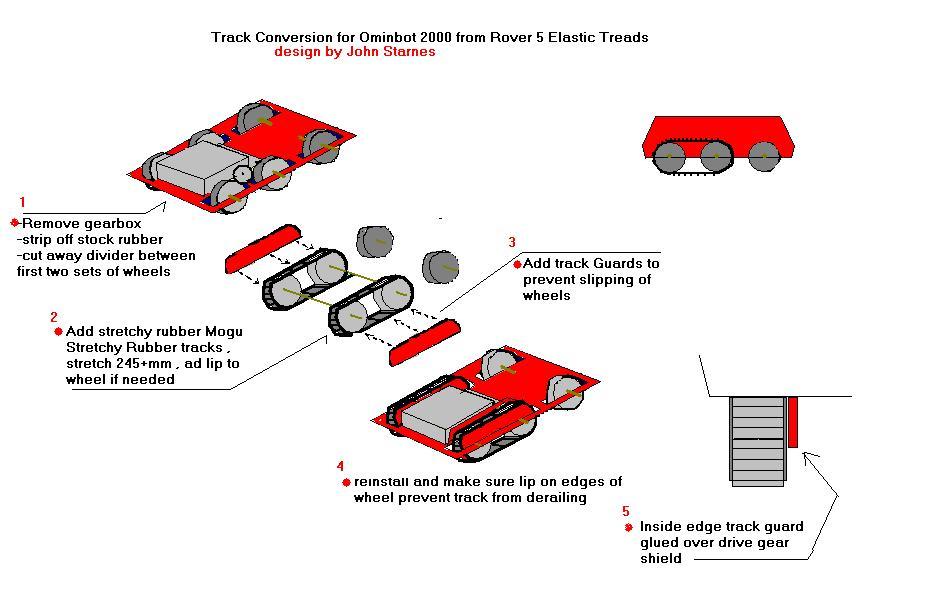
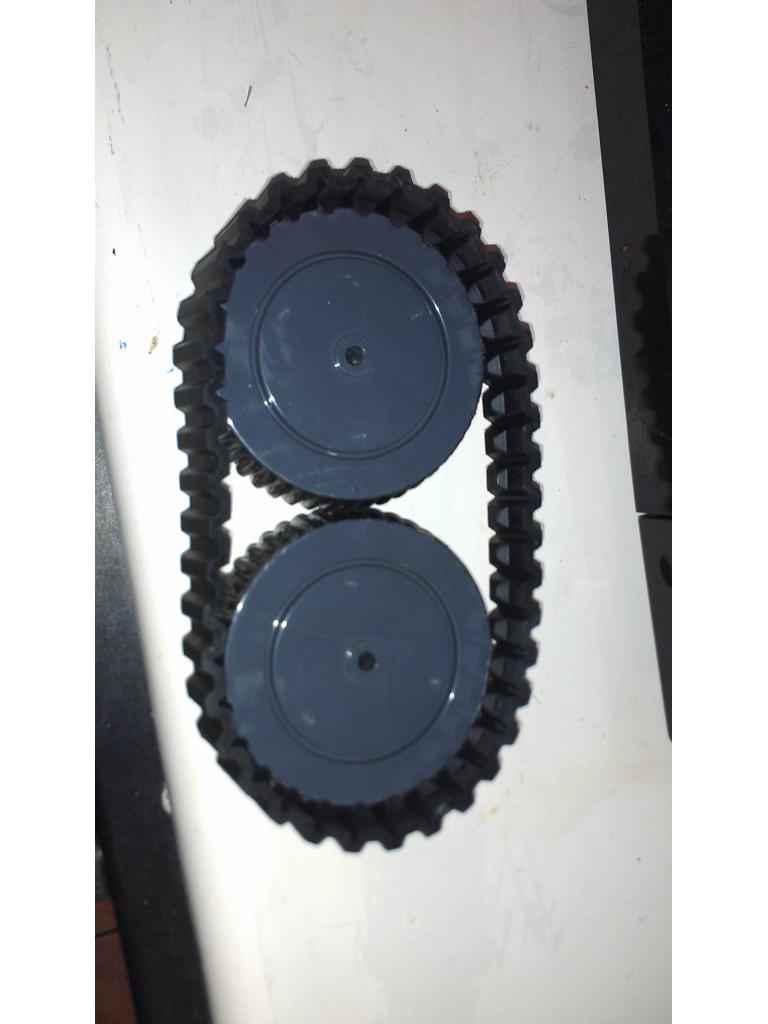
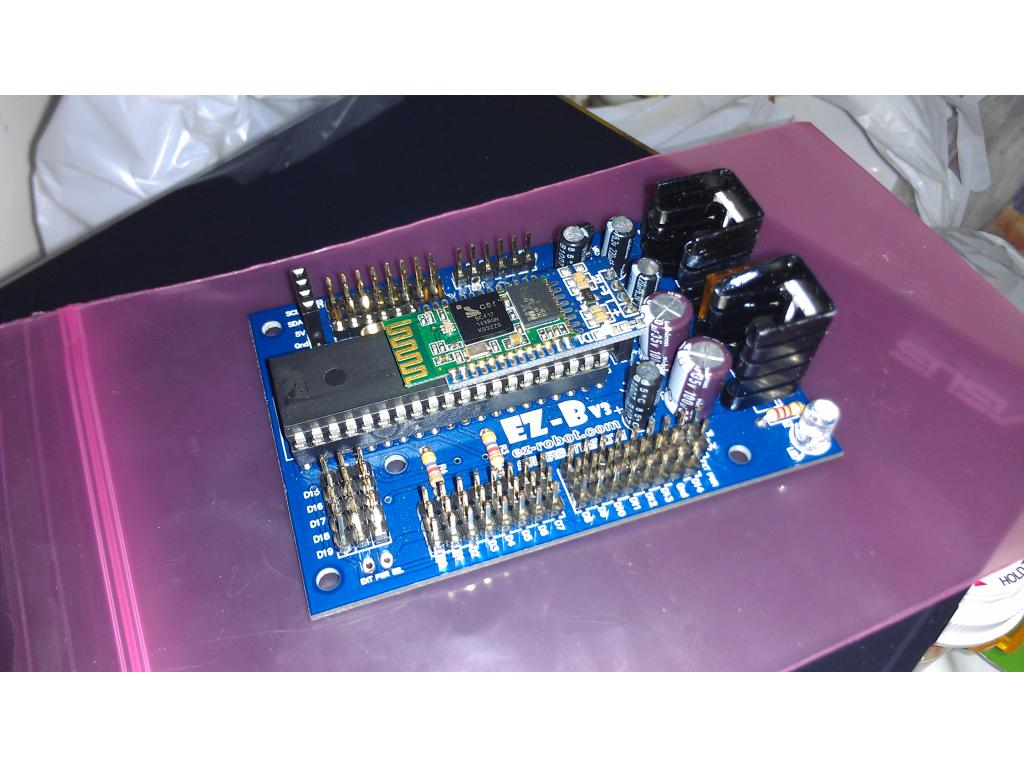
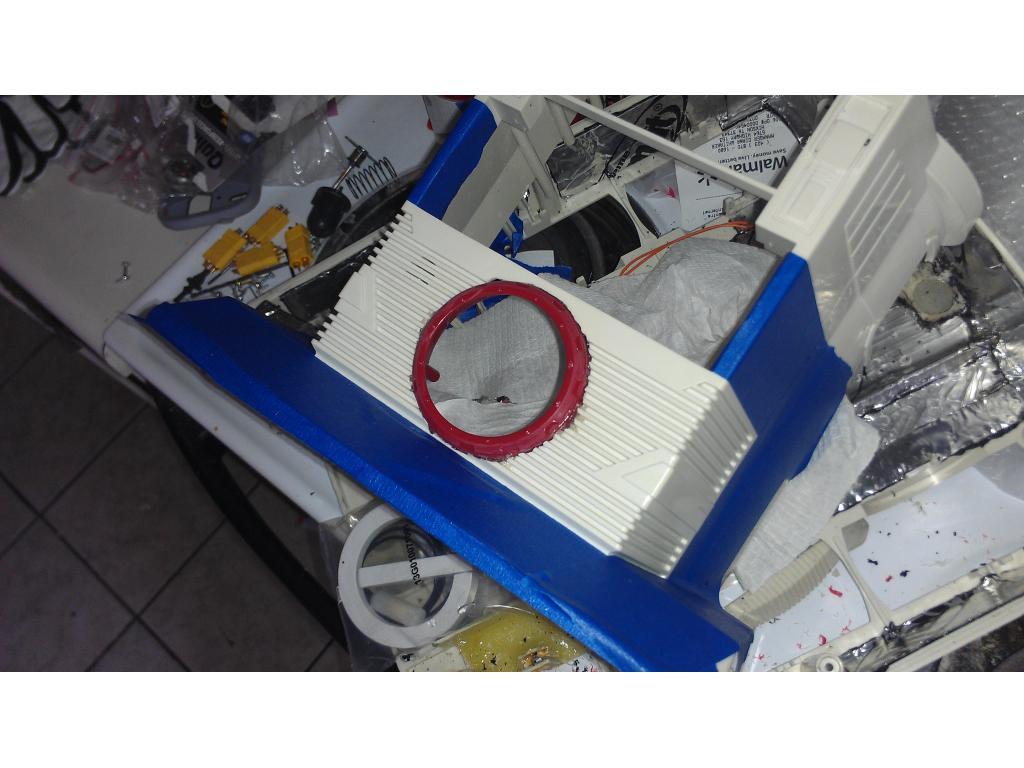
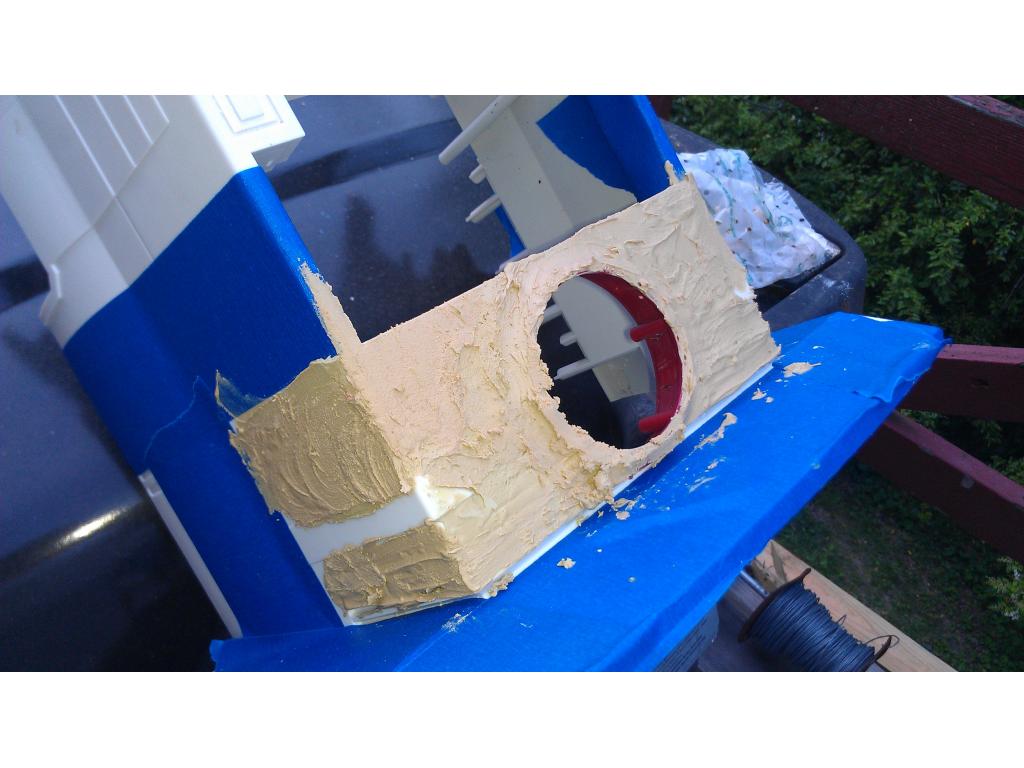
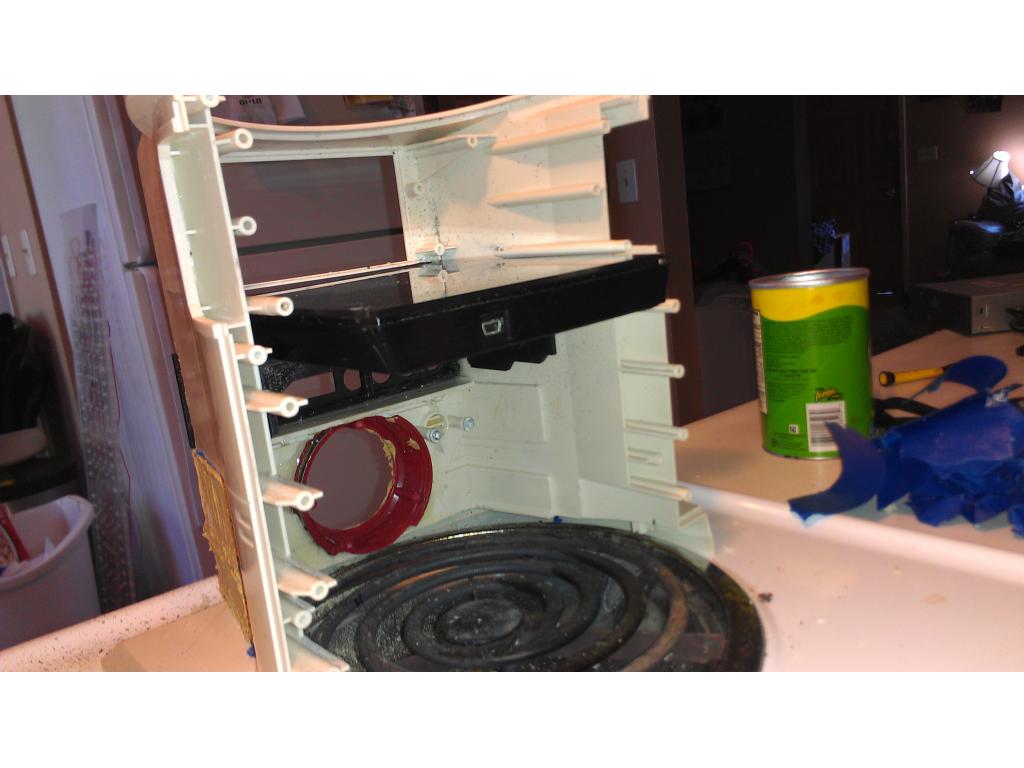
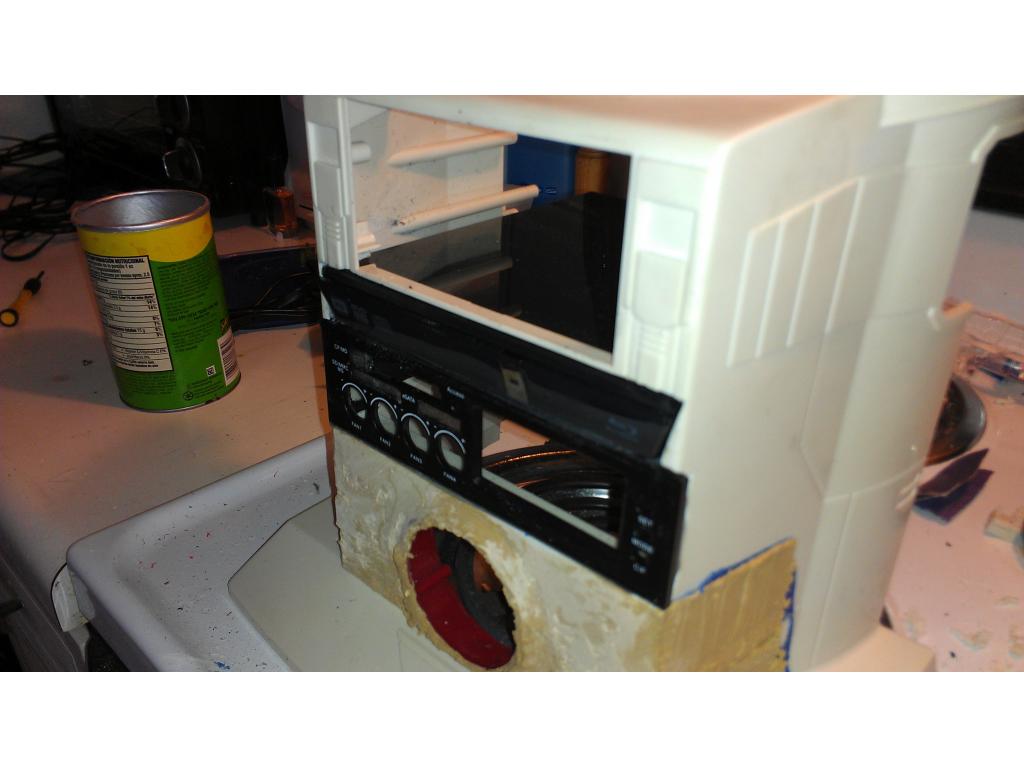
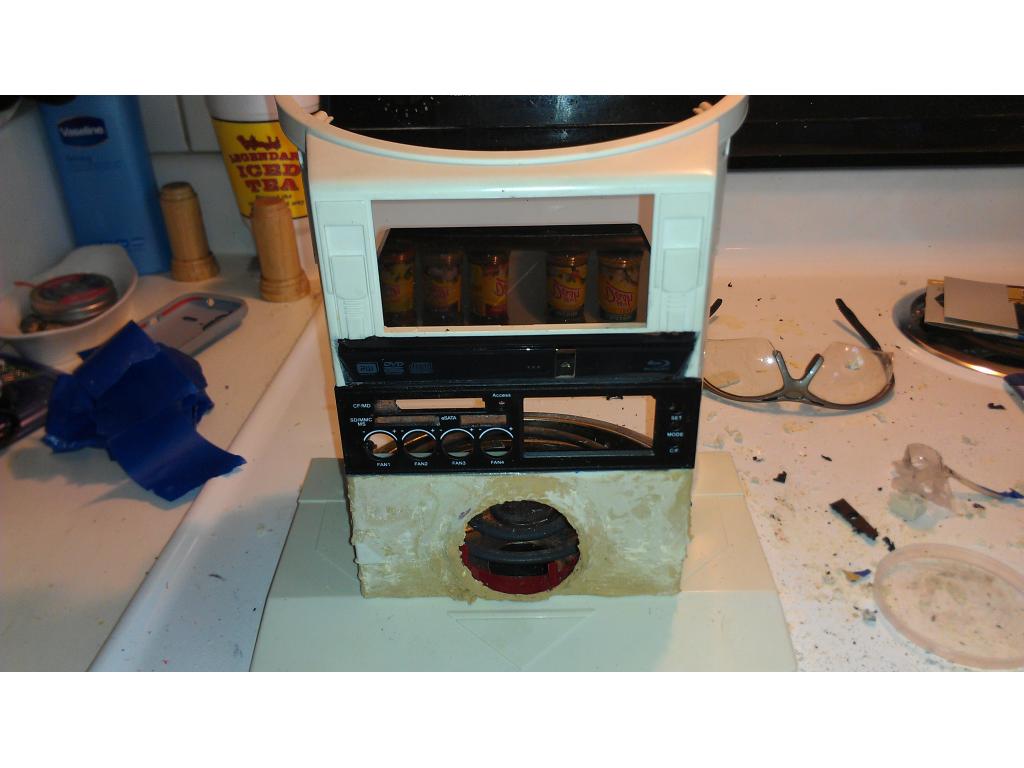
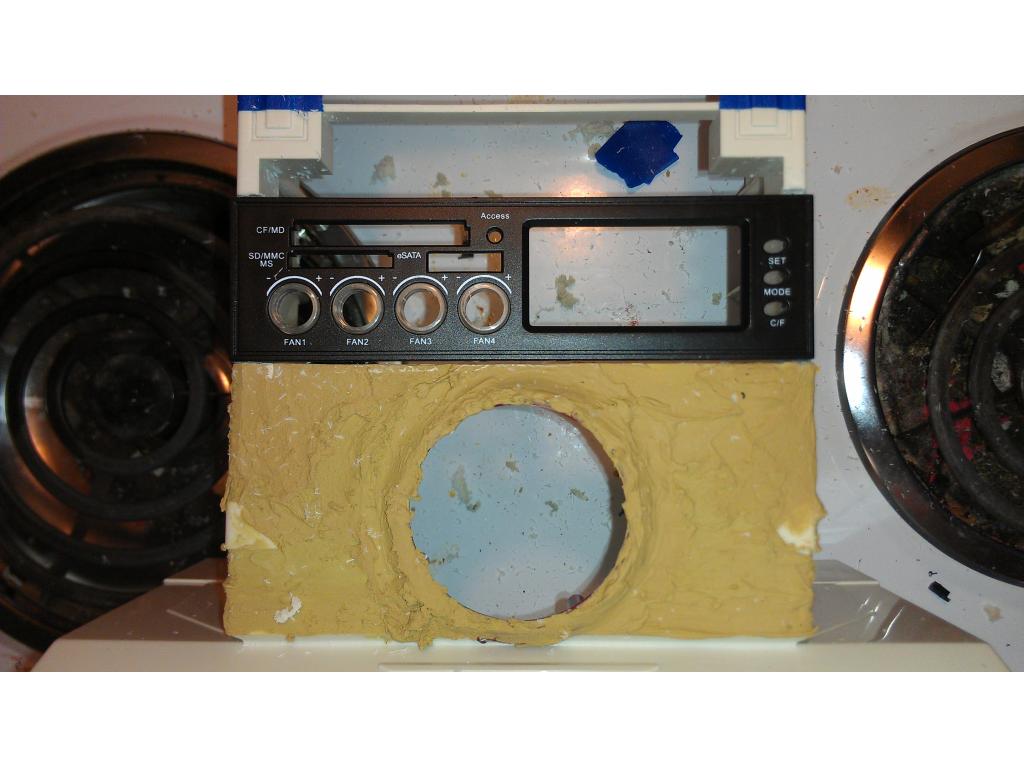
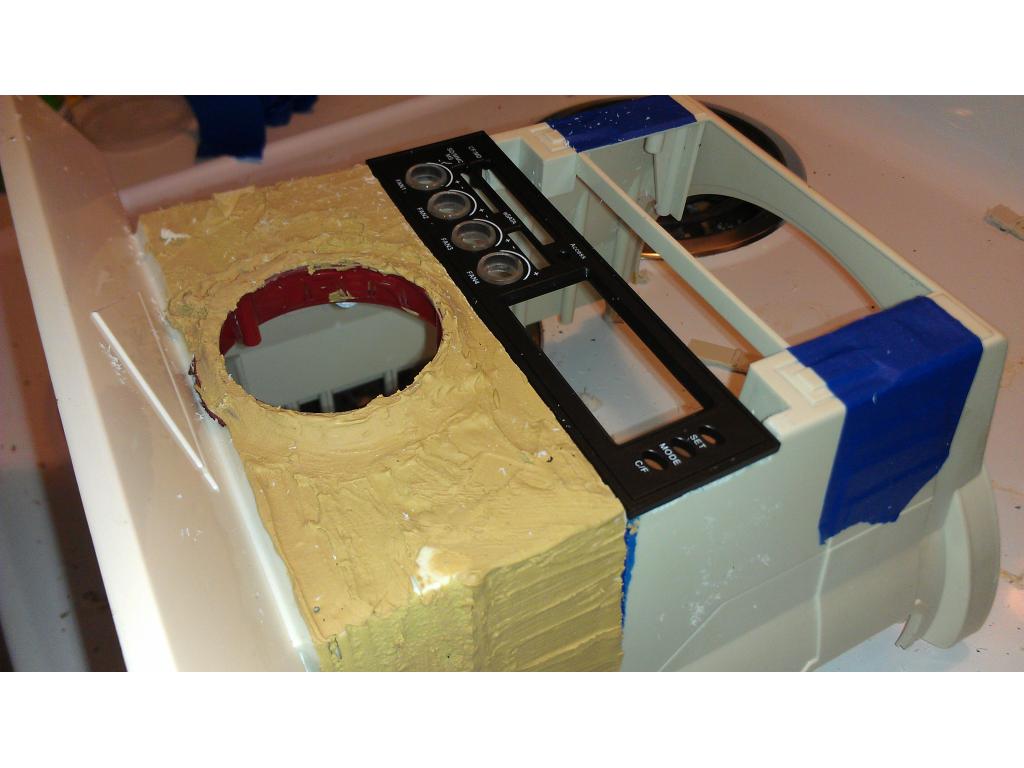
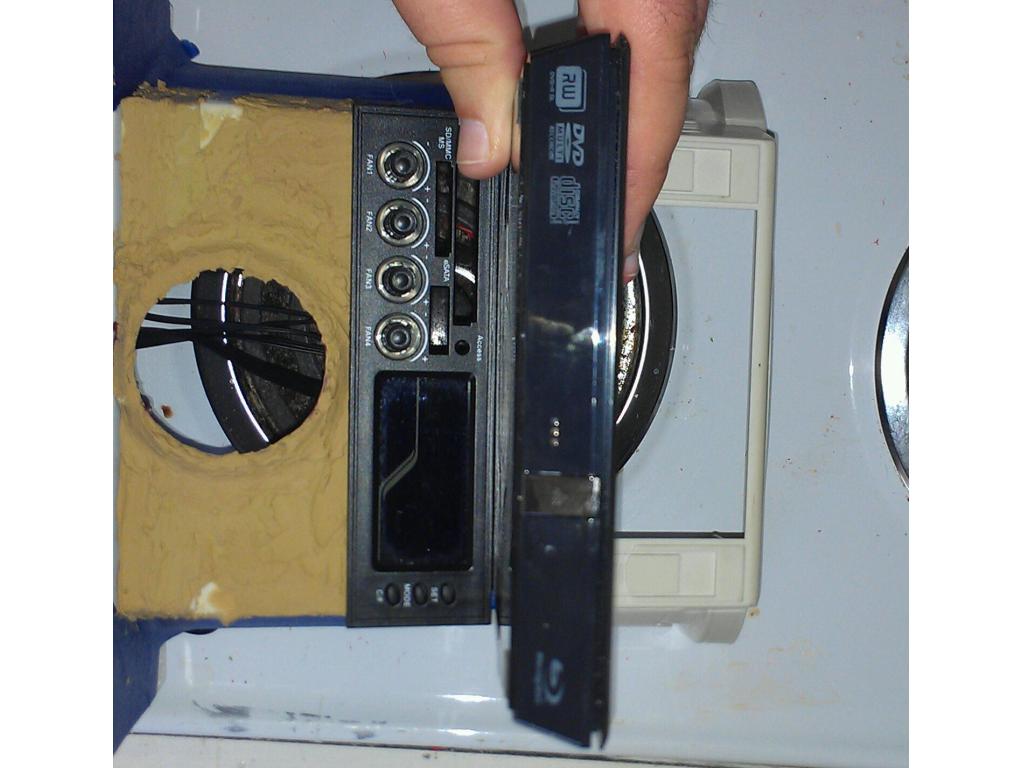
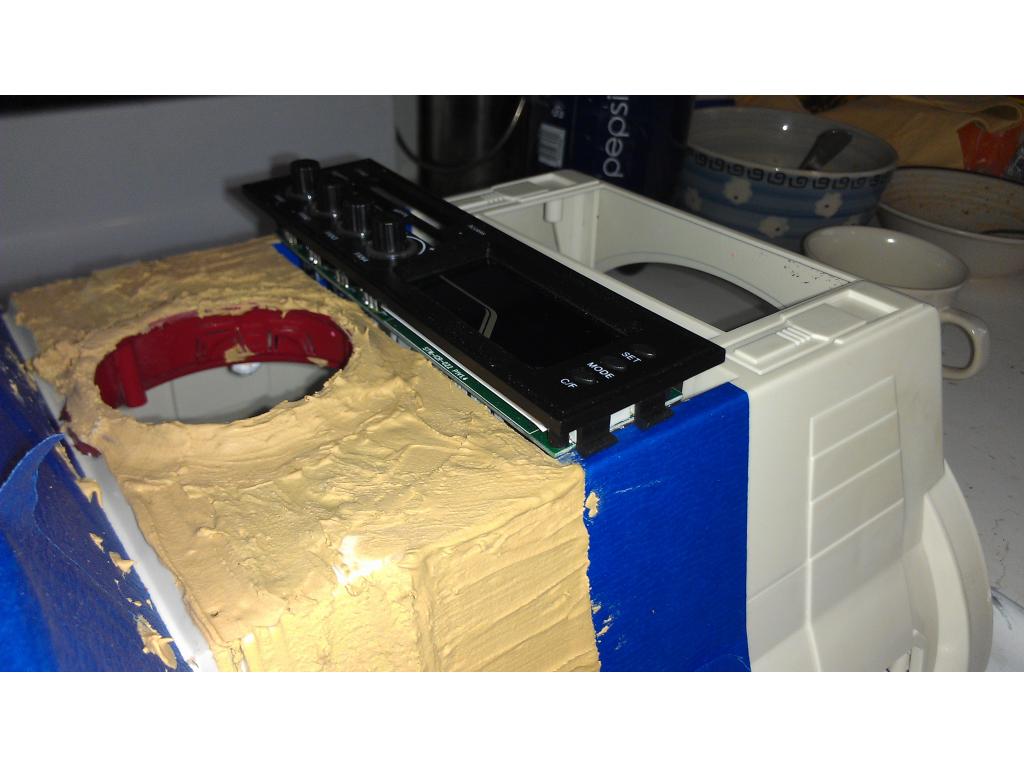
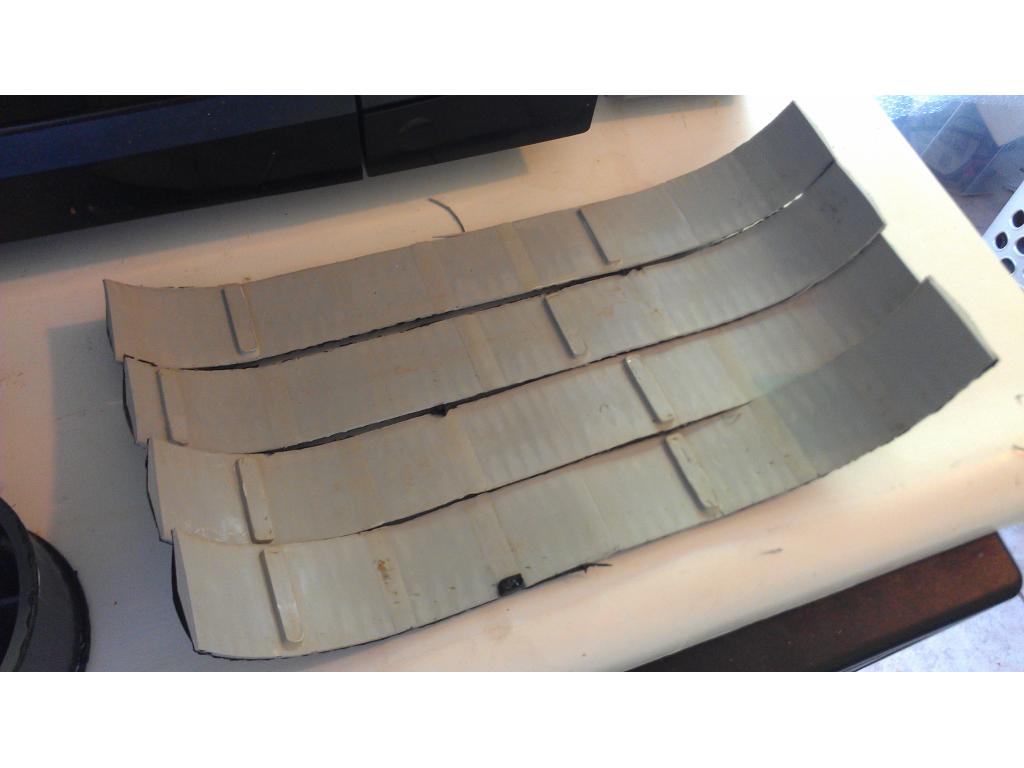
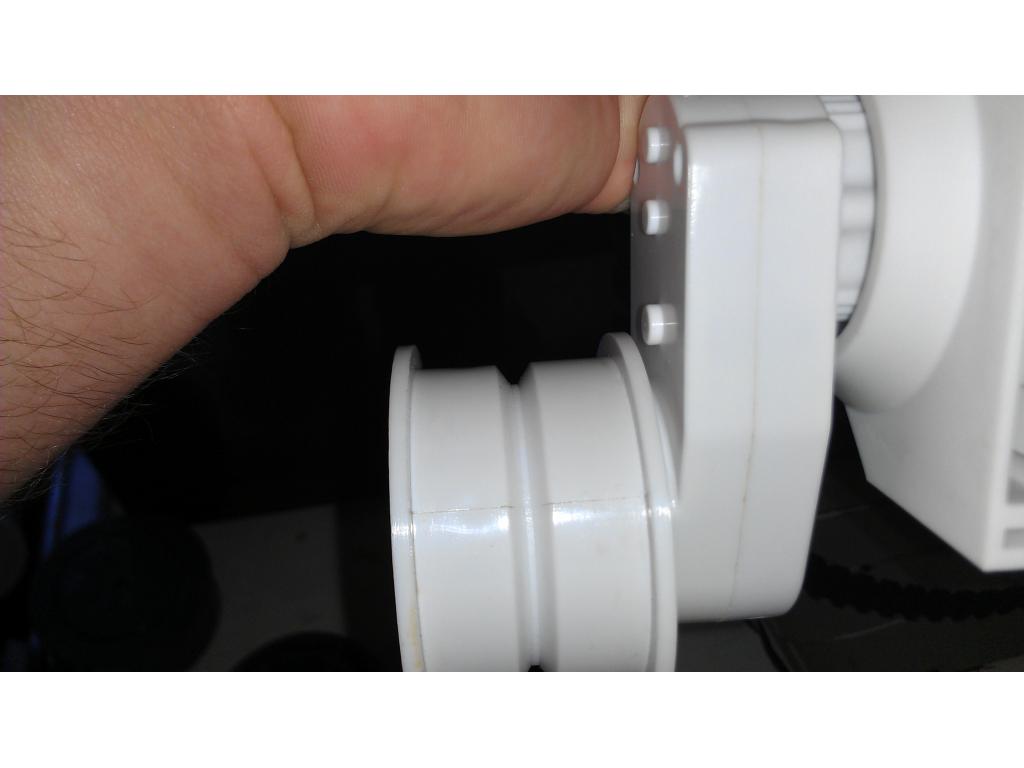
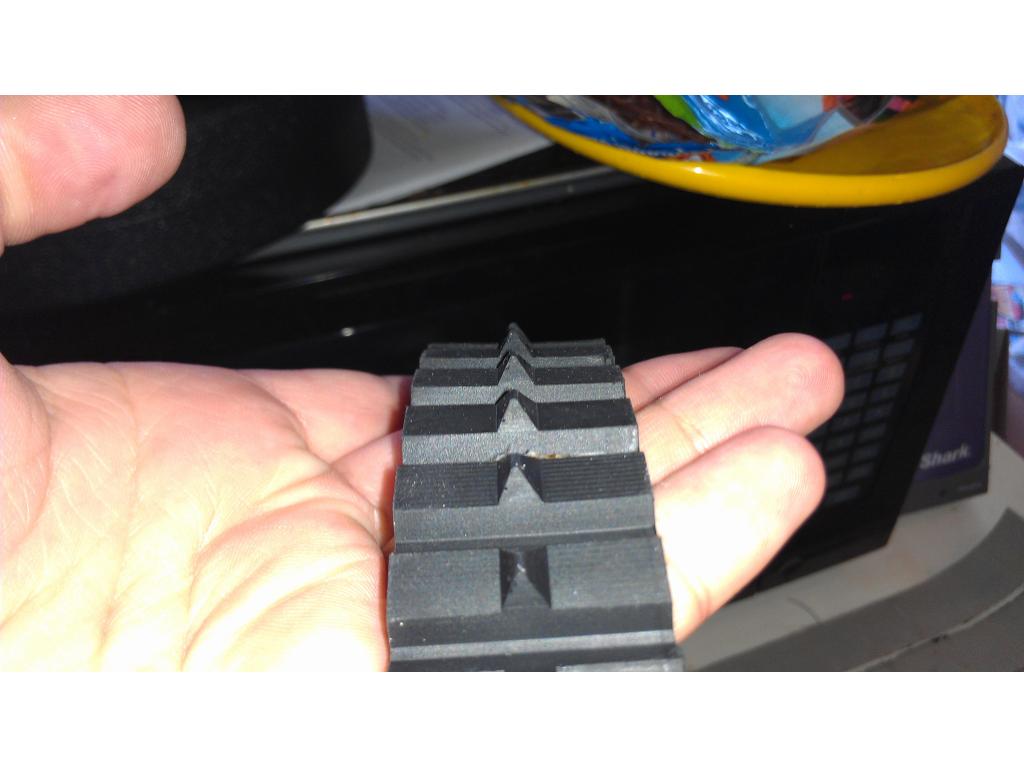
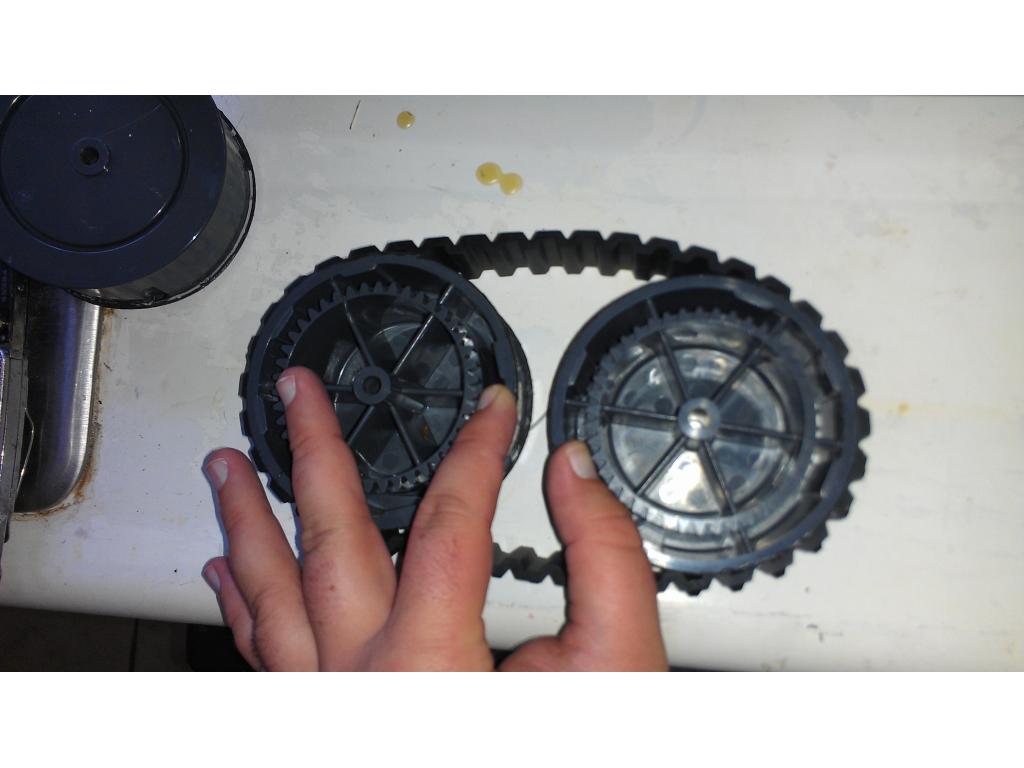
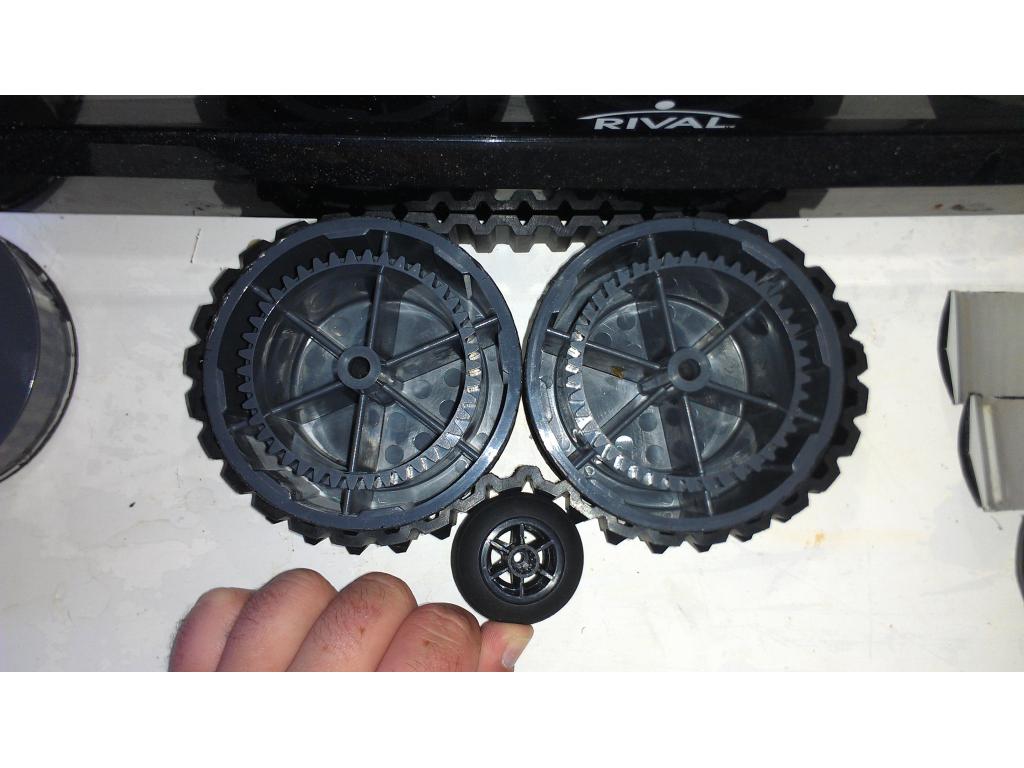
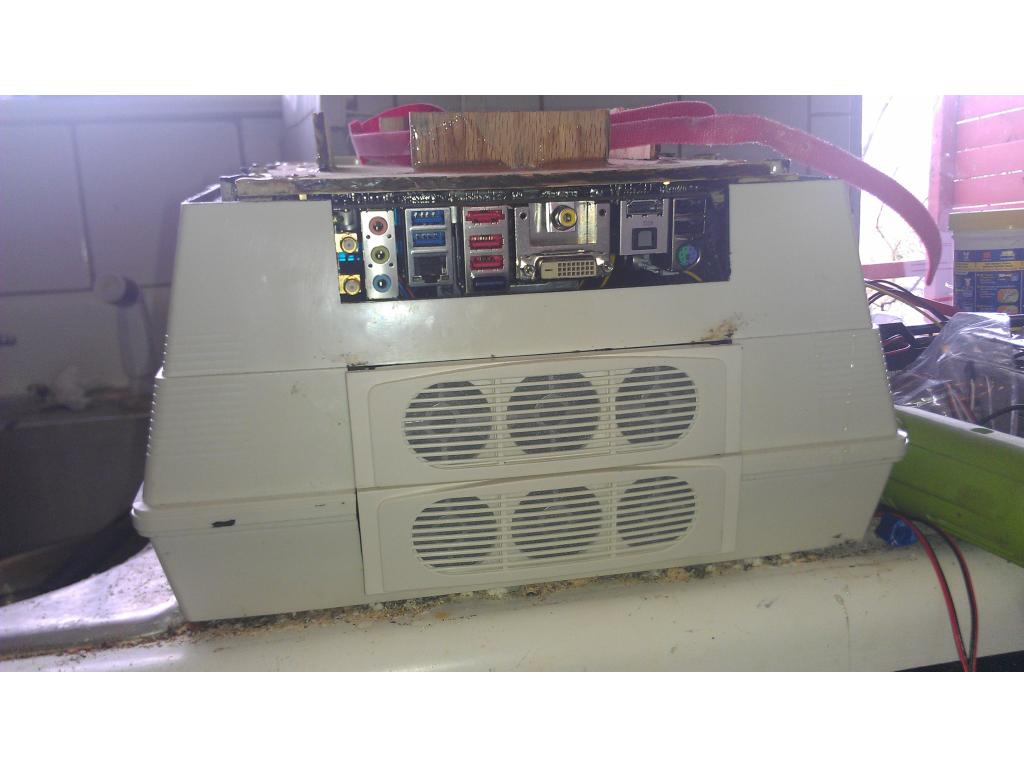
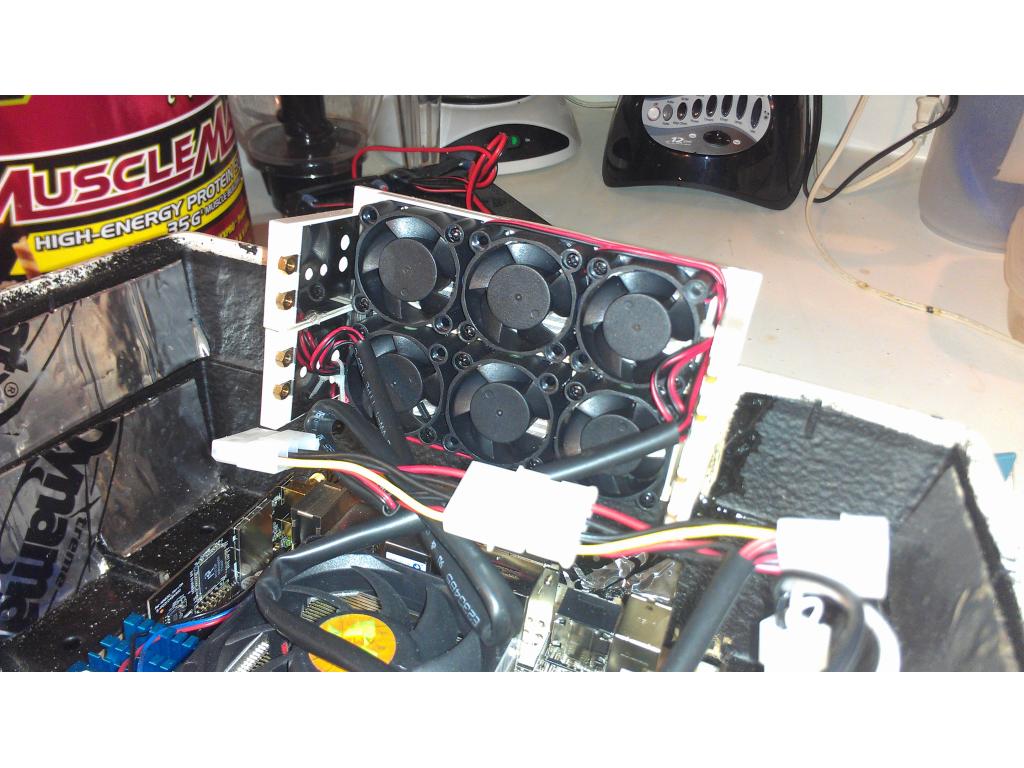
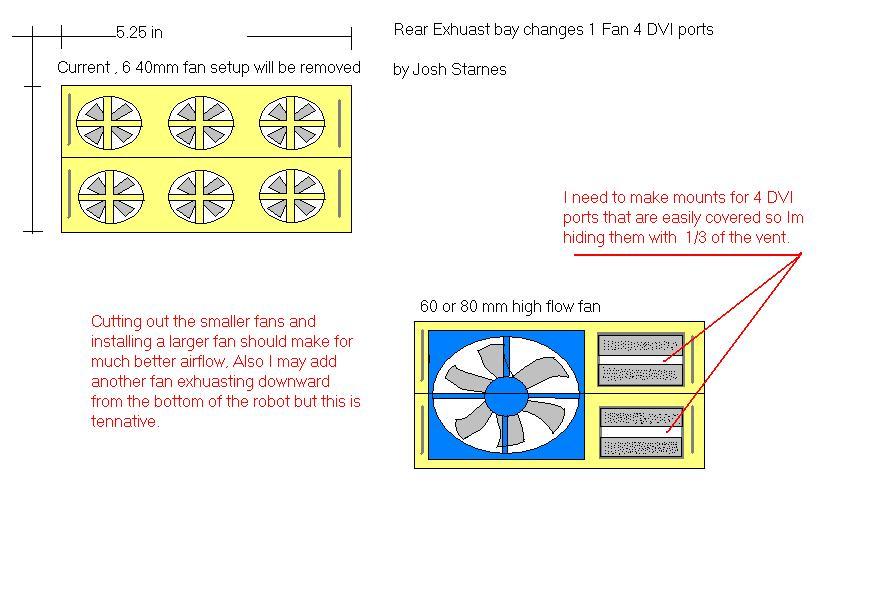
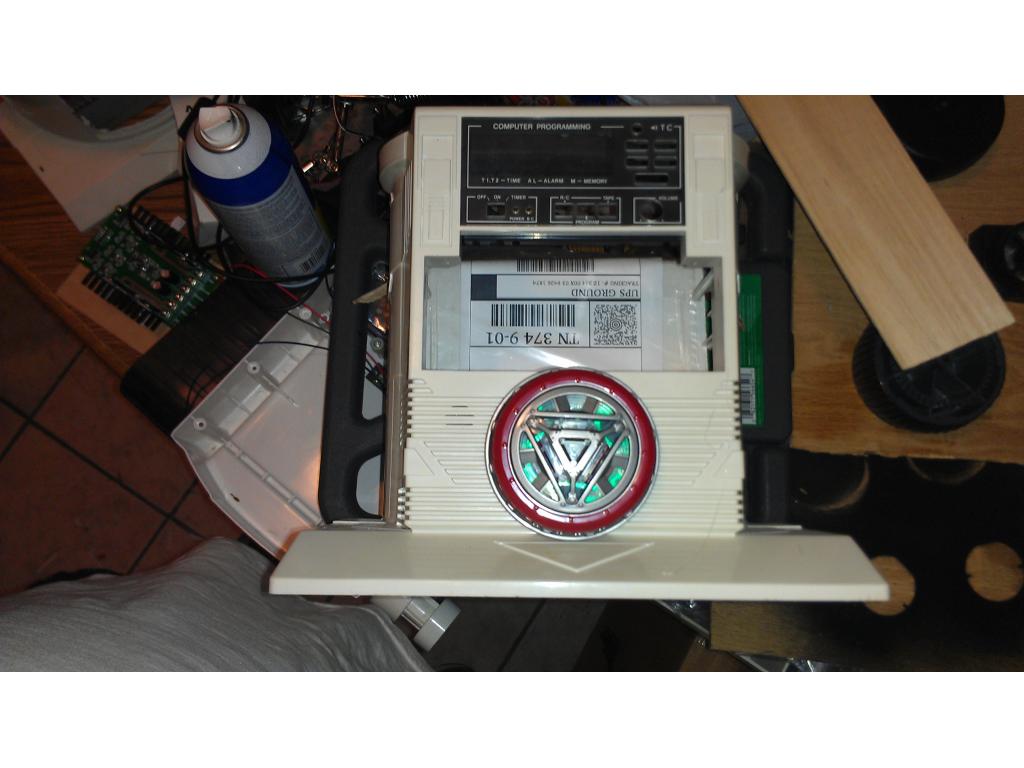
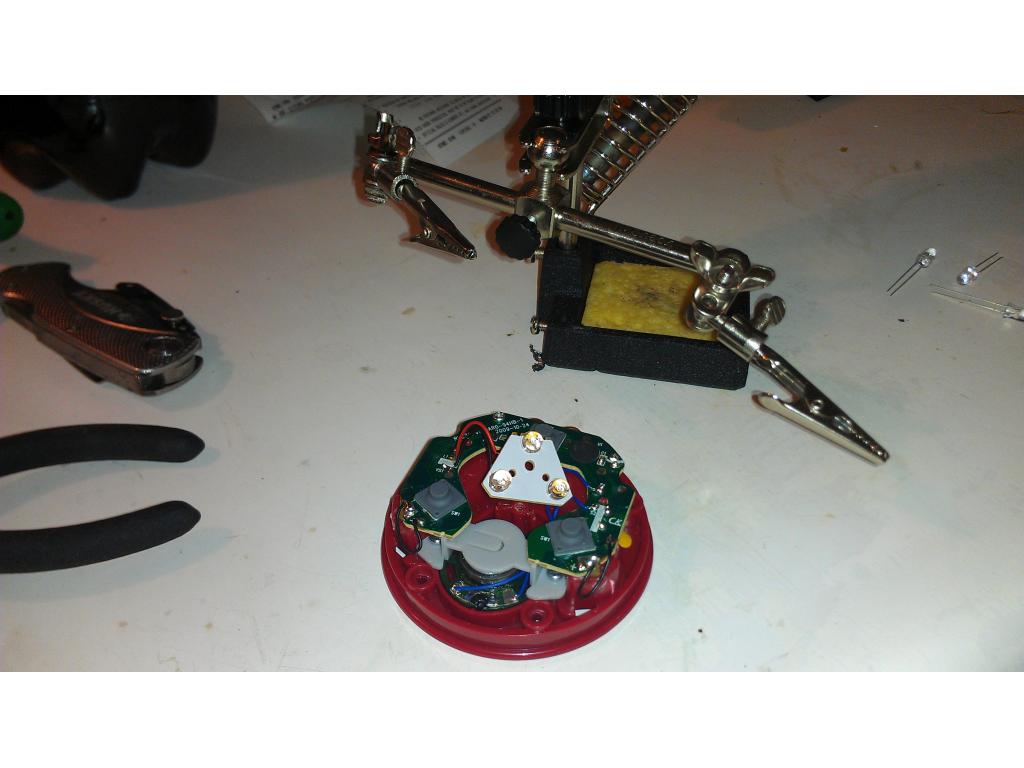
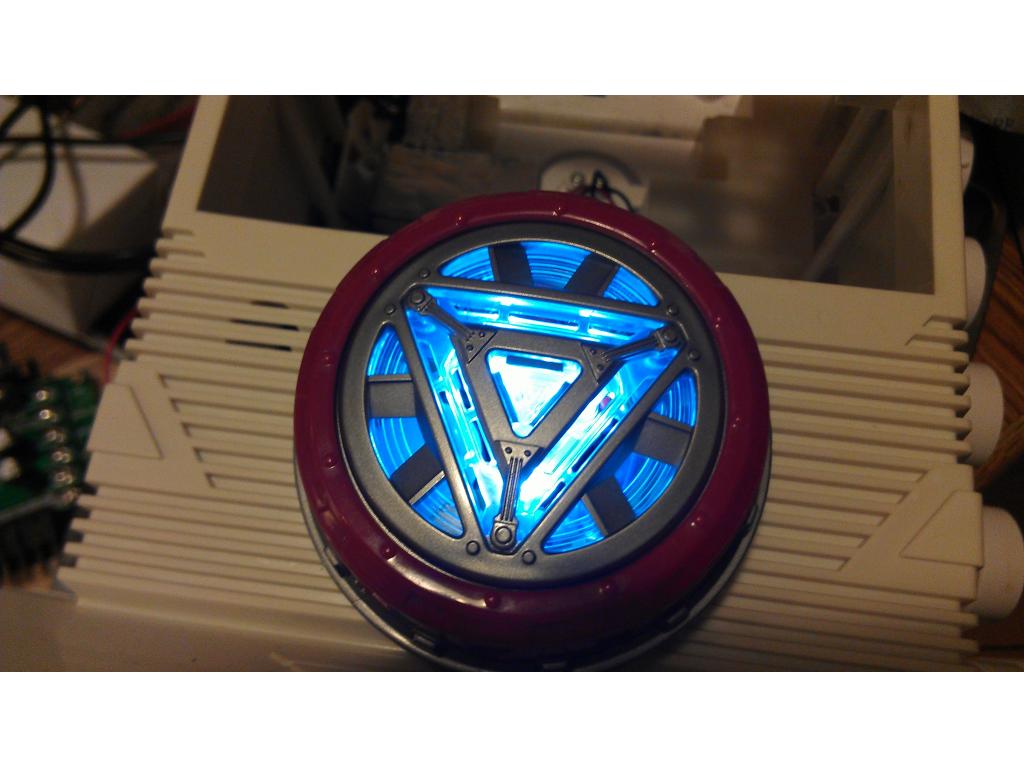
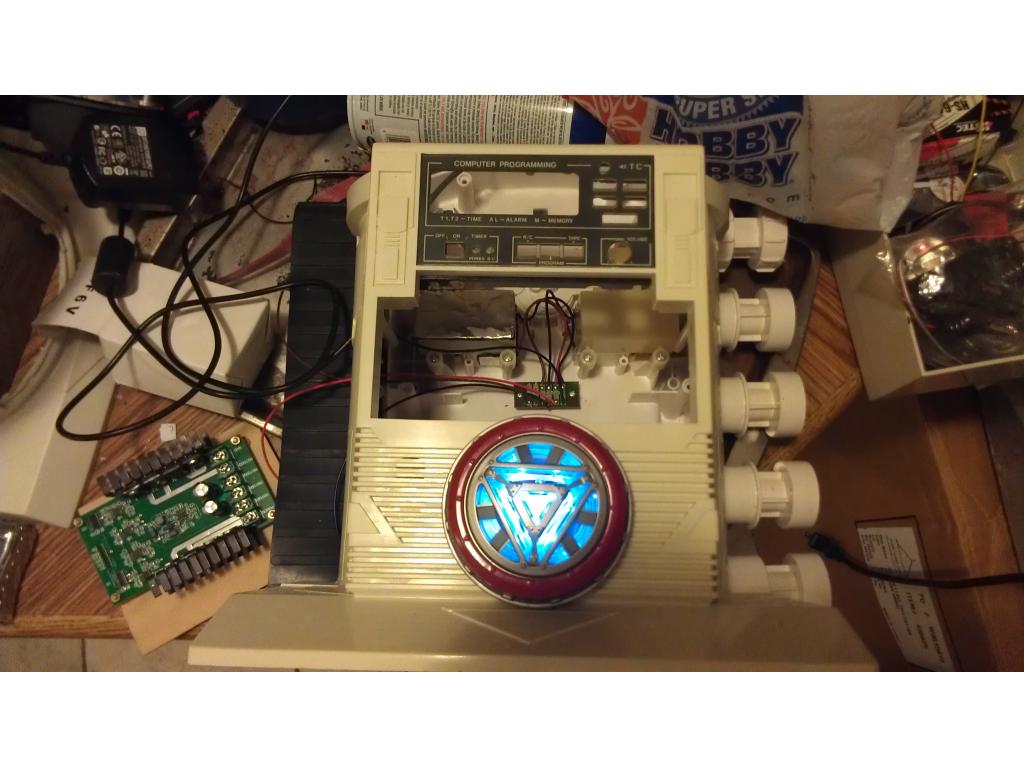
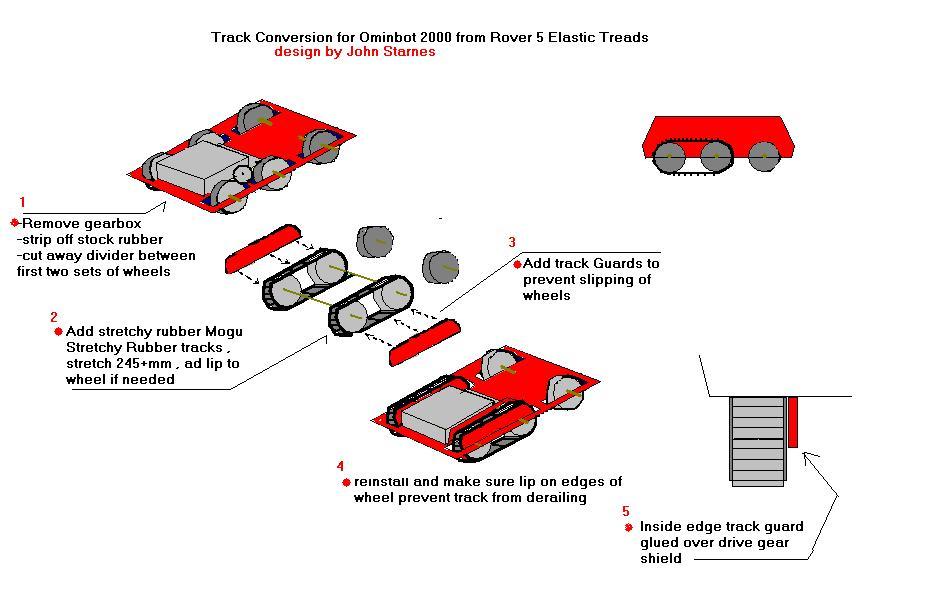
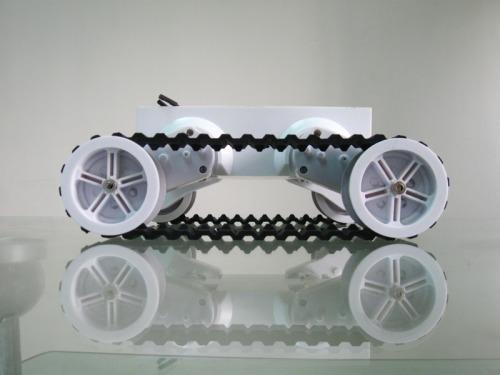
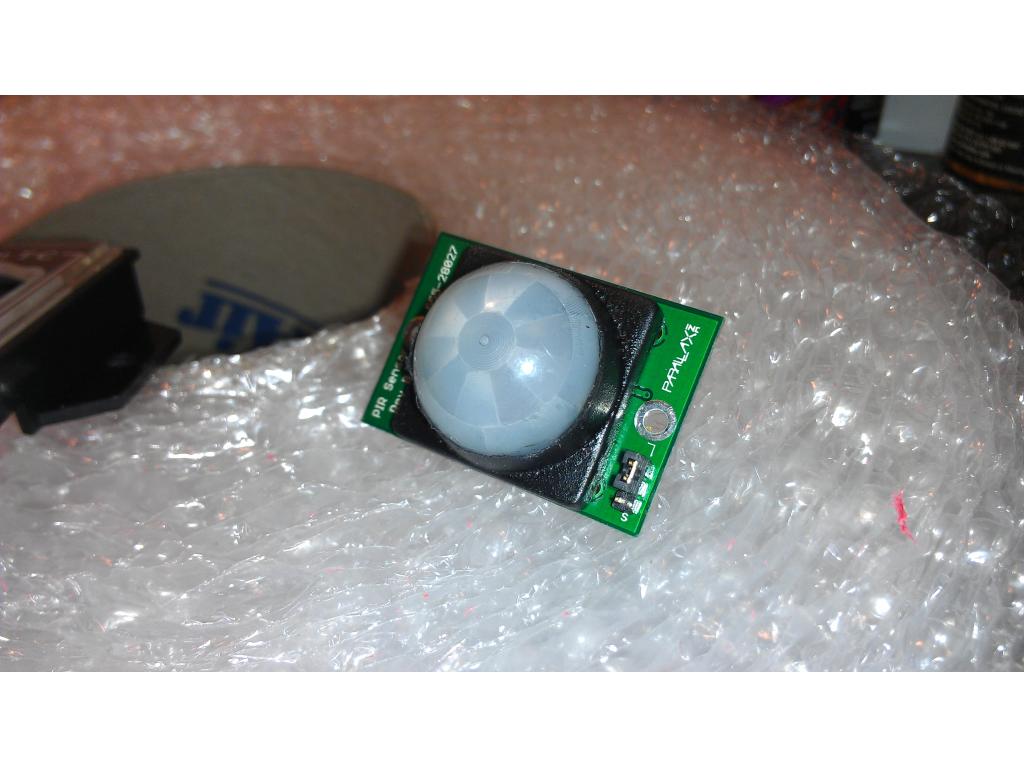
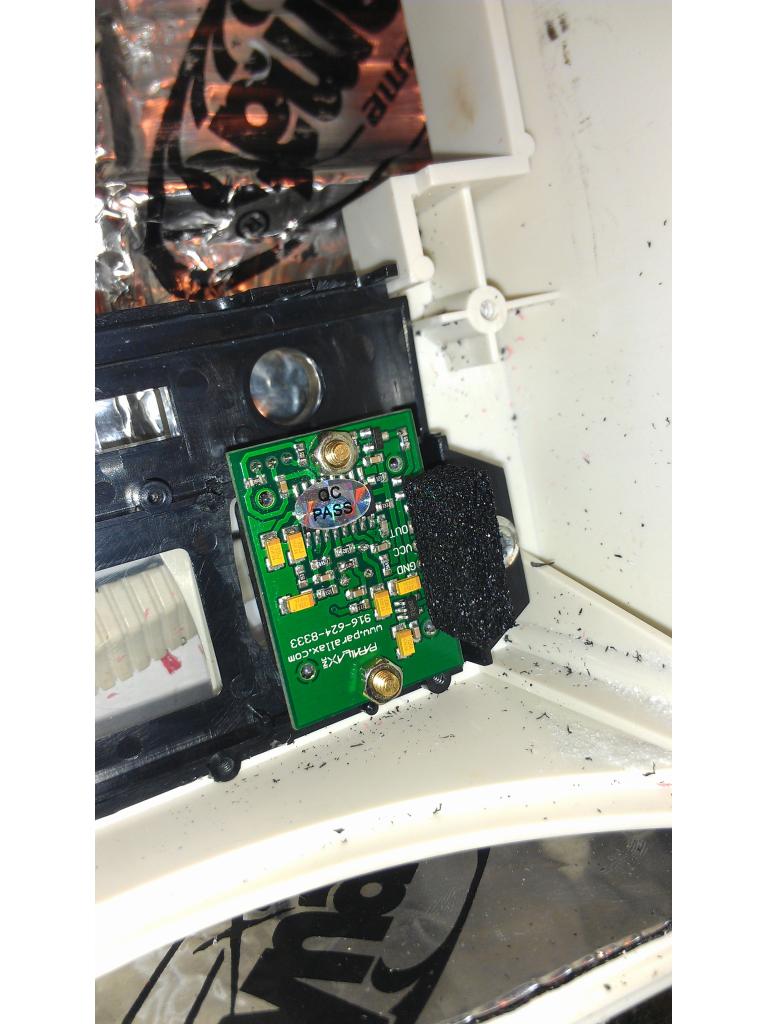
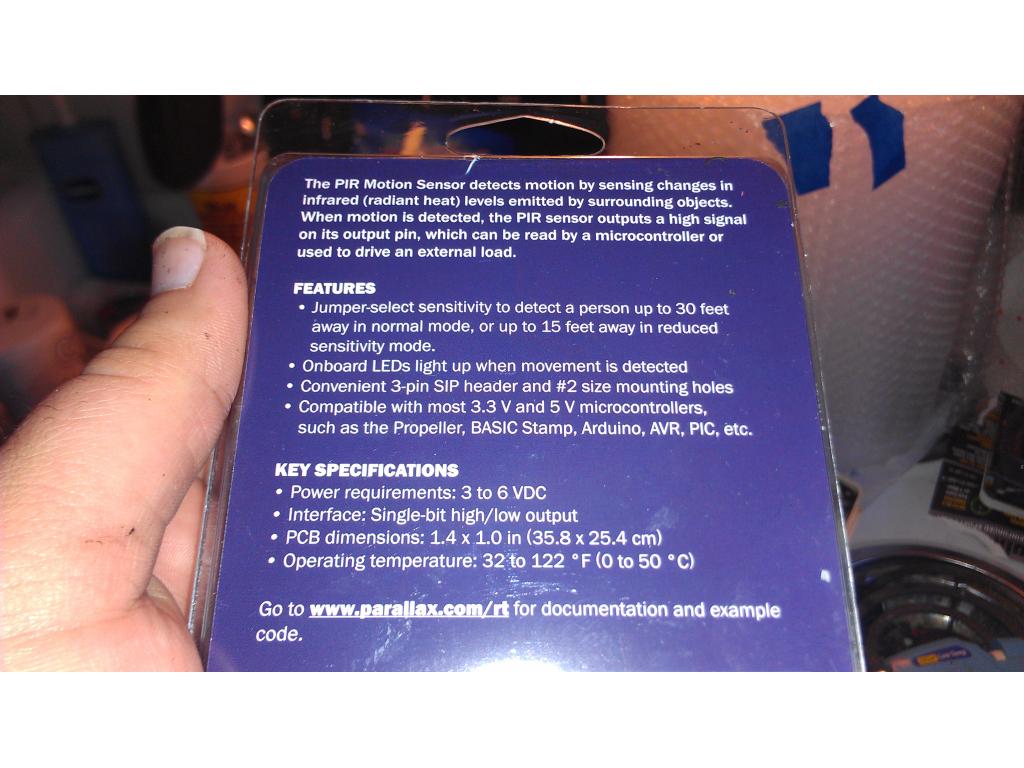
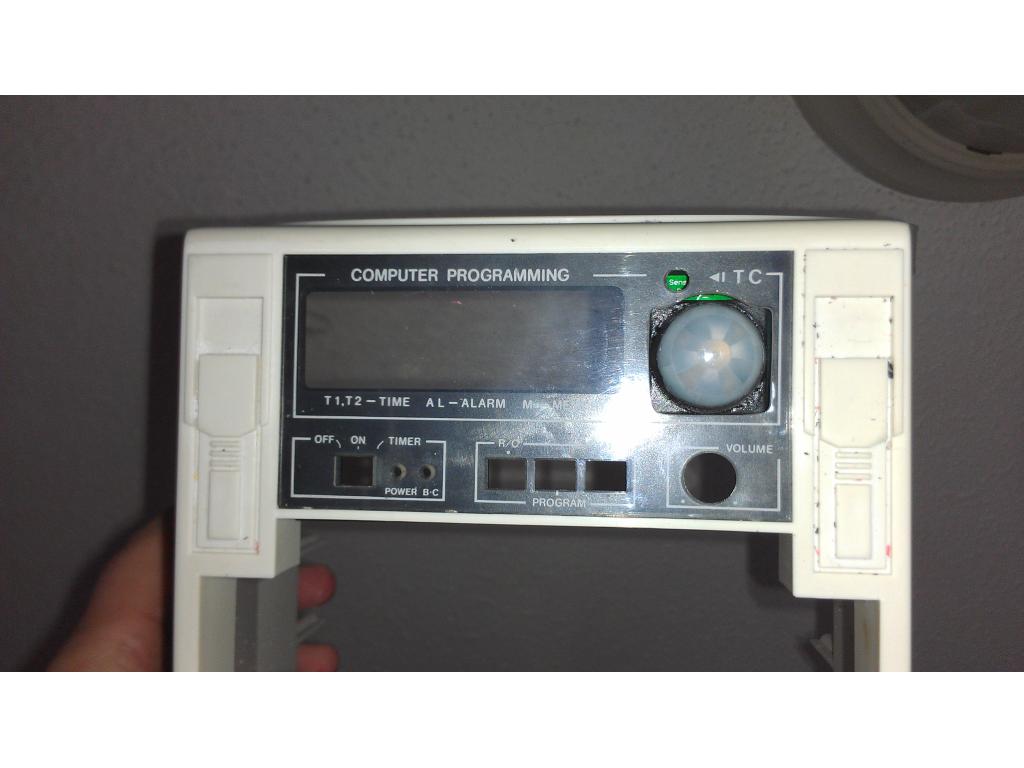
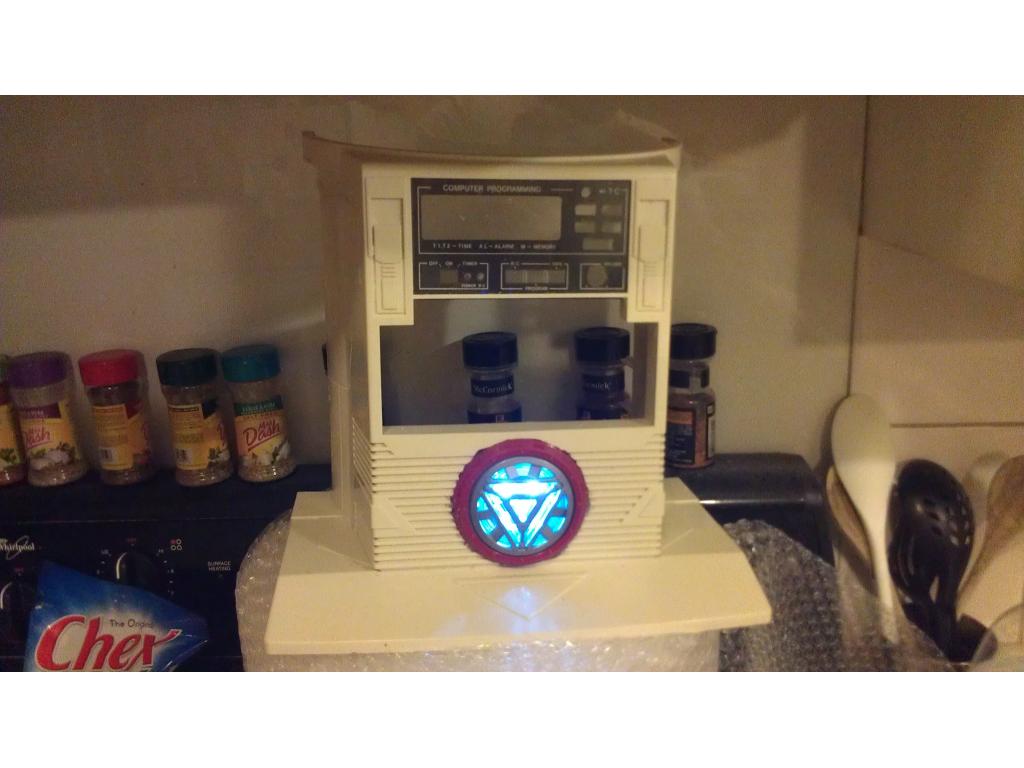
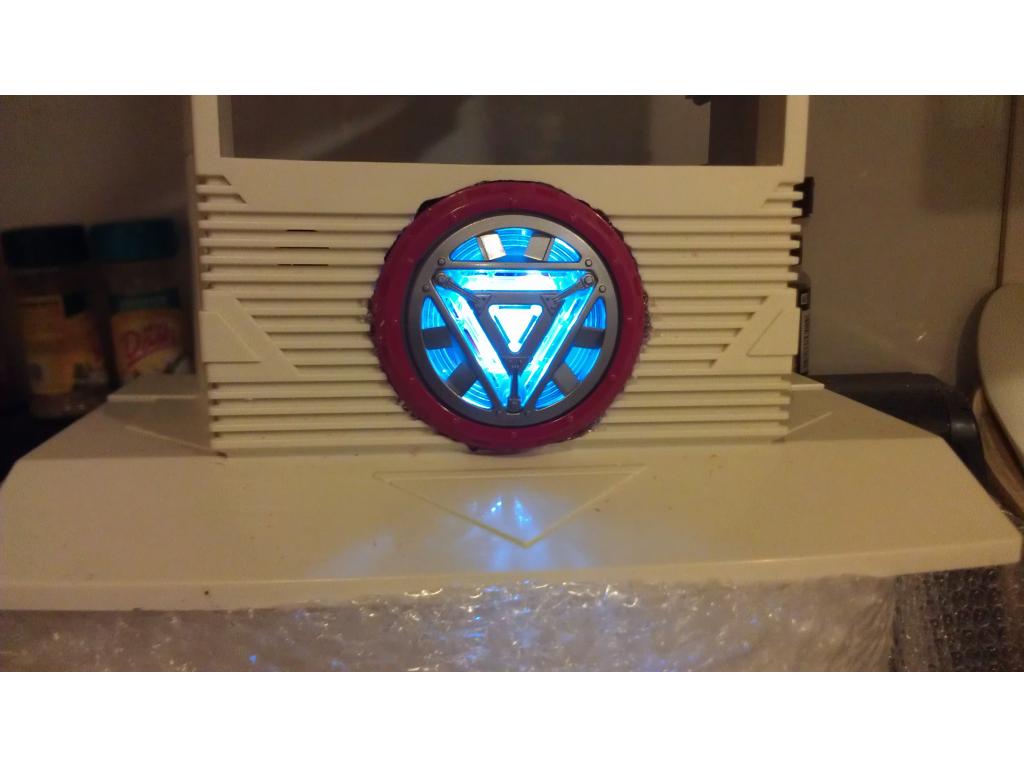
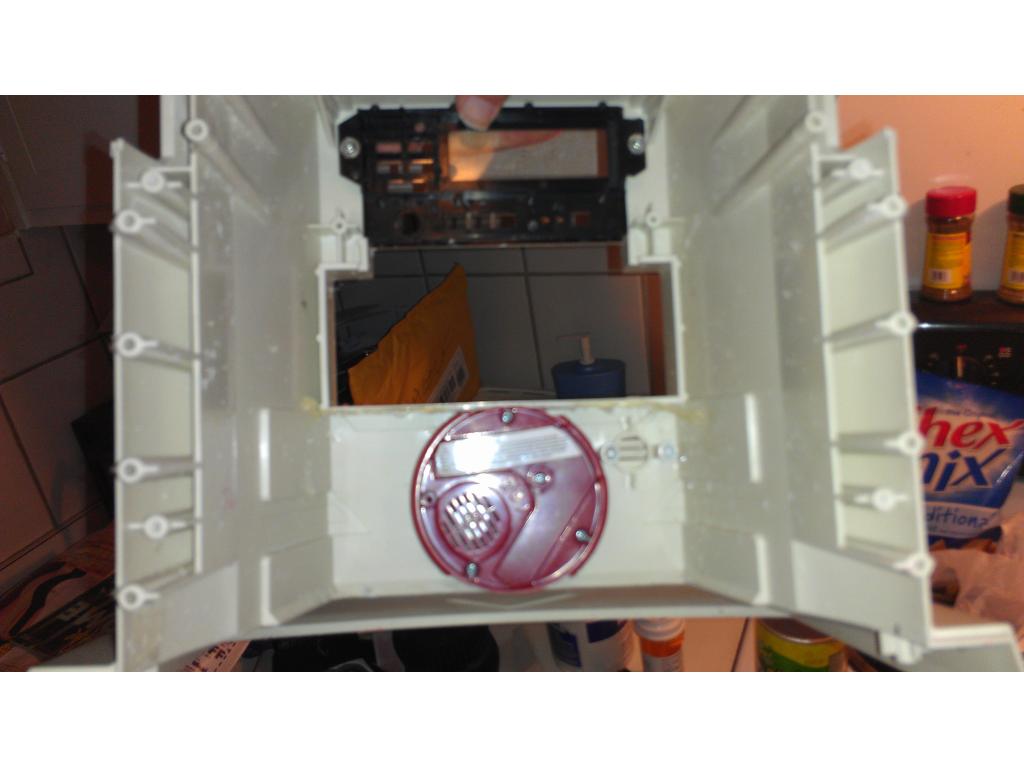
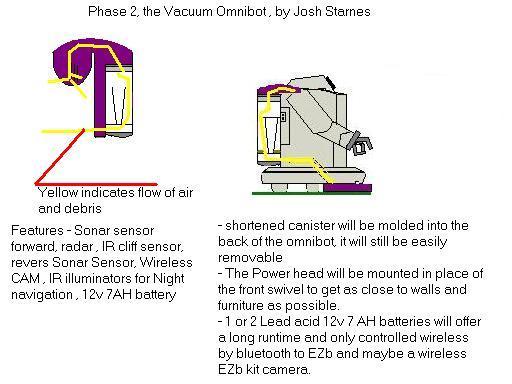
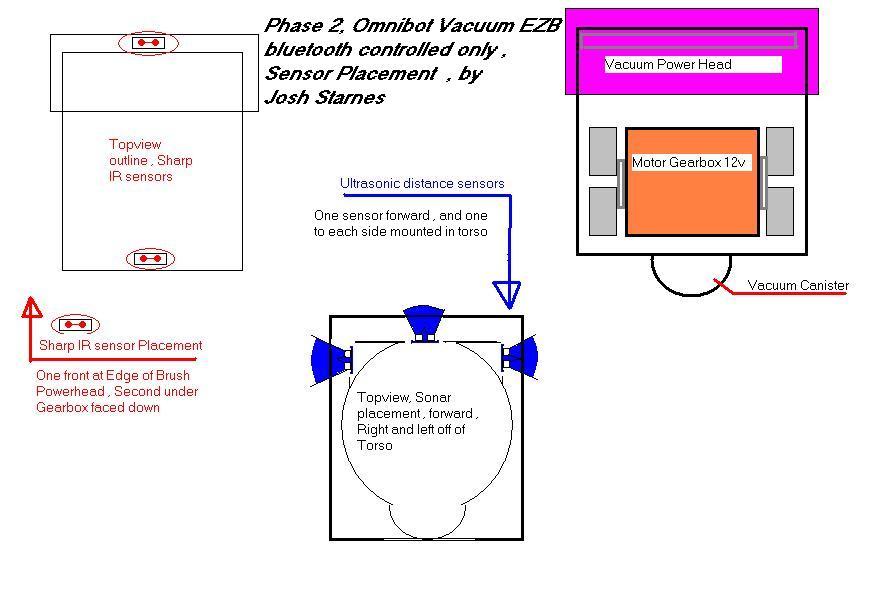
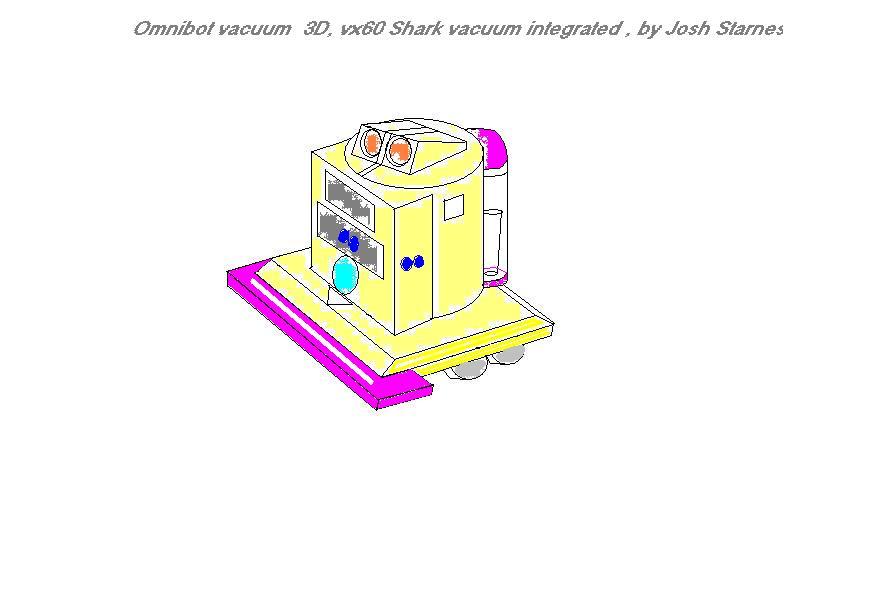
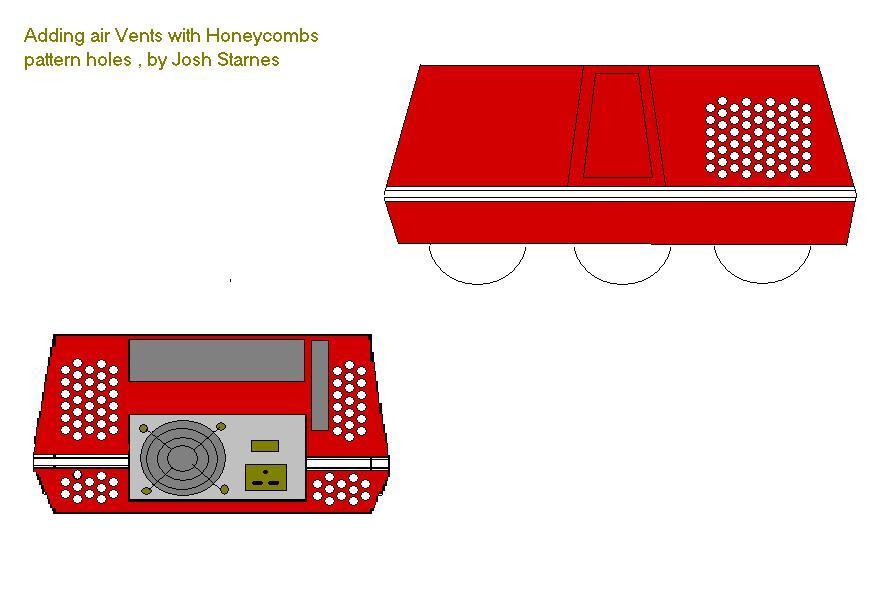
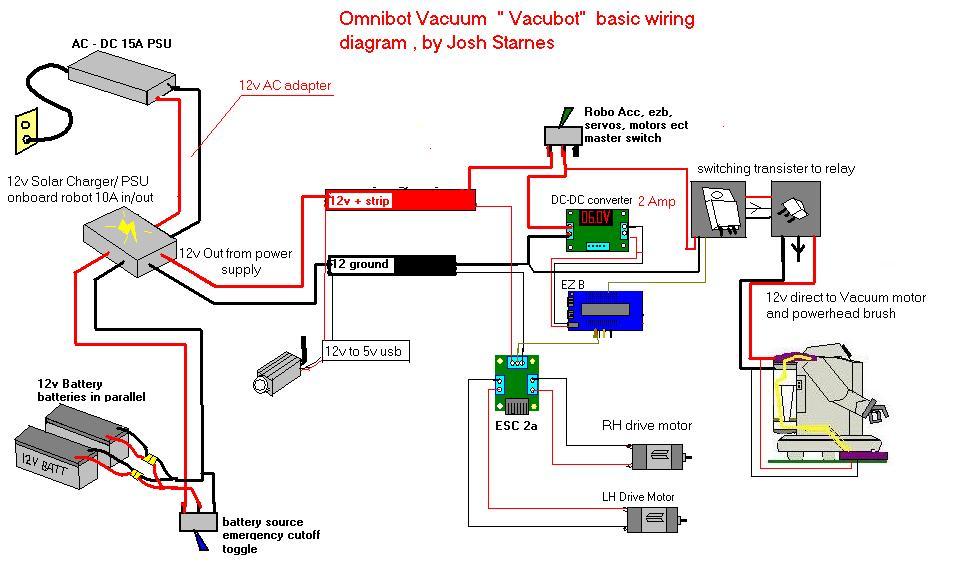
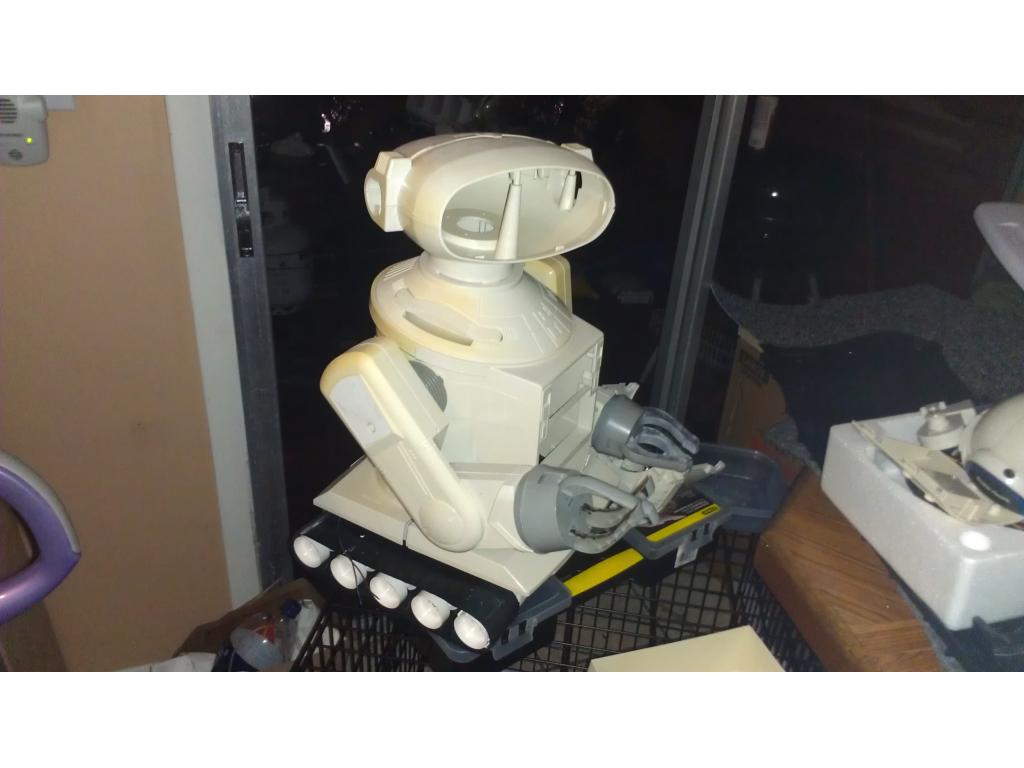
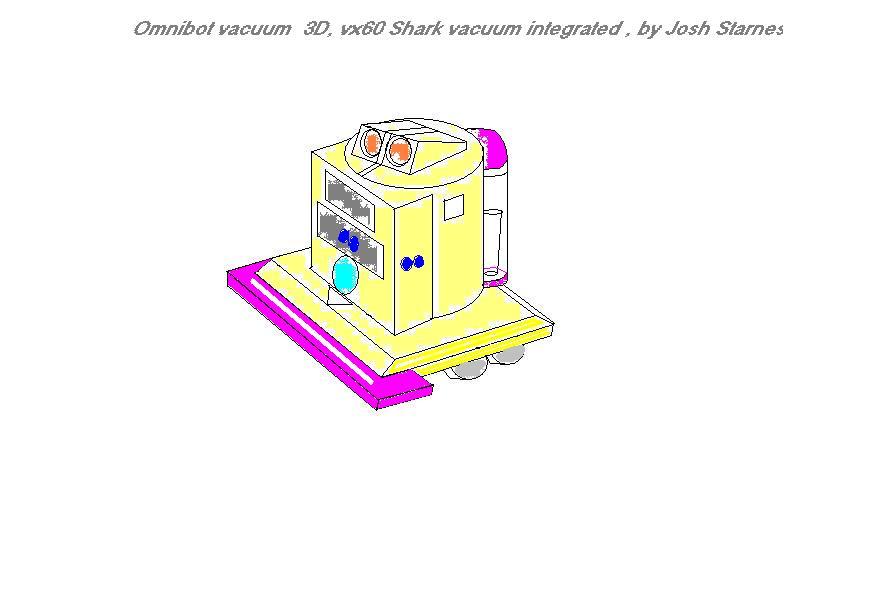
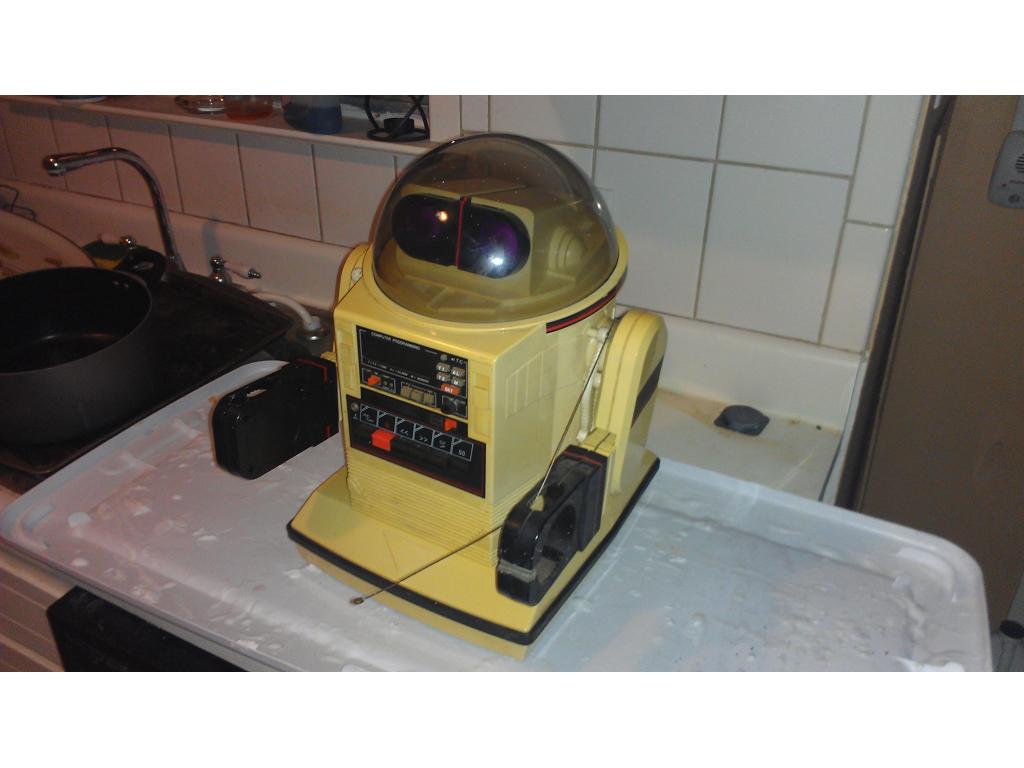
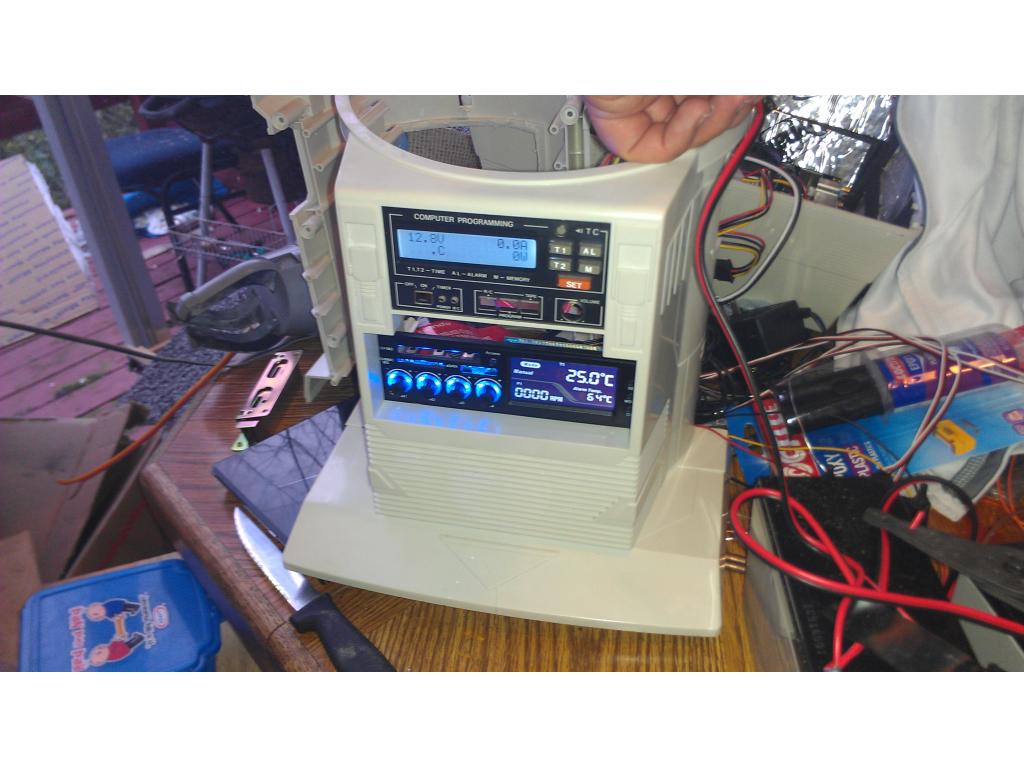
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.
By jstarne1
— Last update
Discover more robots
Ericez's New Synthiam Humanoid On Development
Humanoid robot planned with 21 servos for increased mobility; upper body underway, feet need 10 servos-awaiting parts to...
Doombot's Doombot V1.0
DoomBot V1.0 - 5-ft robot with wheelchair drive, DC window motor arms, pneumatic cylinder and sculpted exoskeleton...
Rich's My Project Jarvis
Build a physical JARVIS robot with RAD V1 and EZ-B using Synthiam ARC, scripting and house automation integration for...

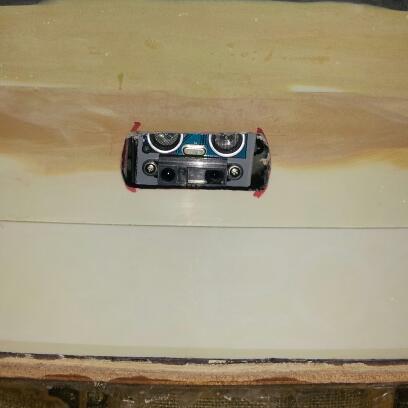
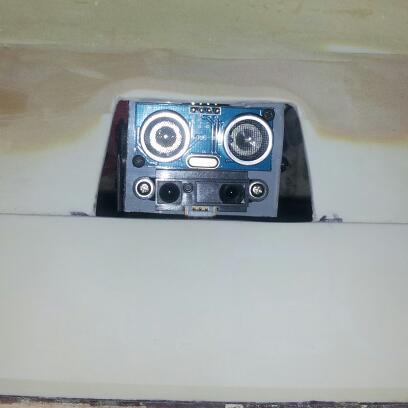
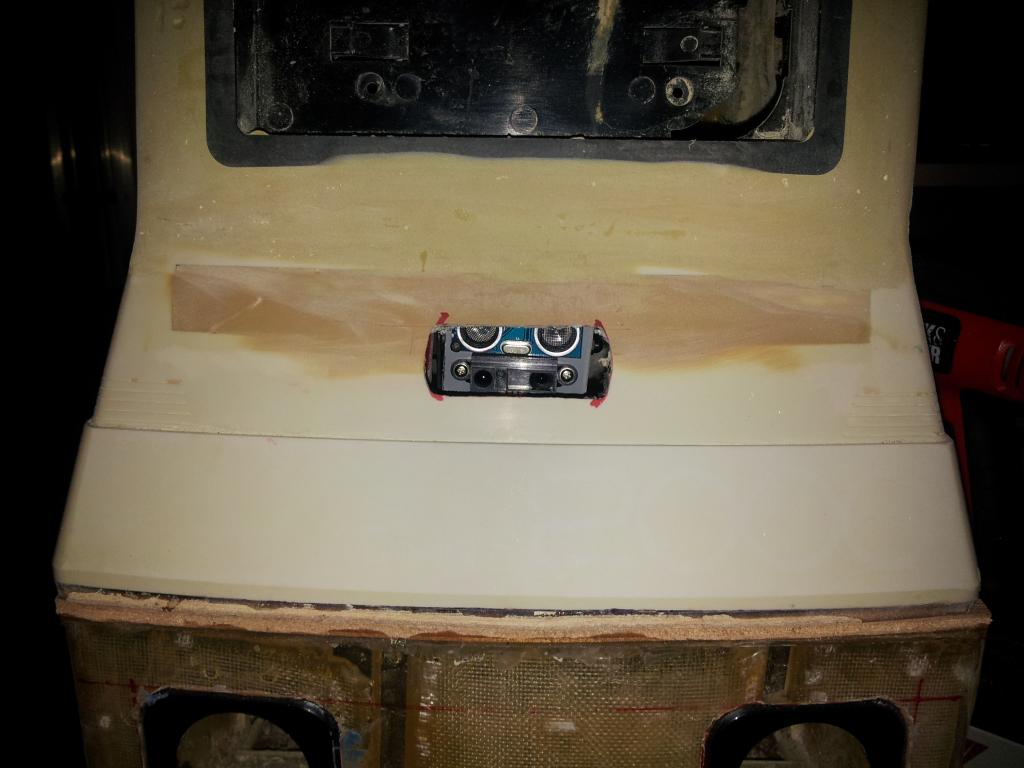
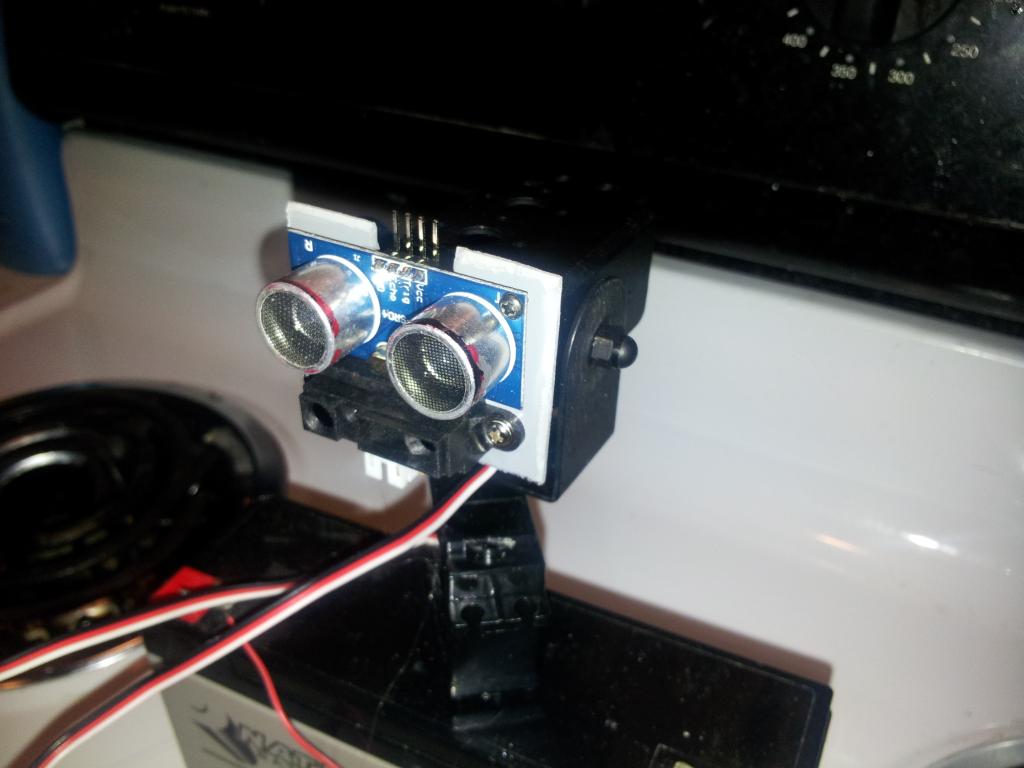
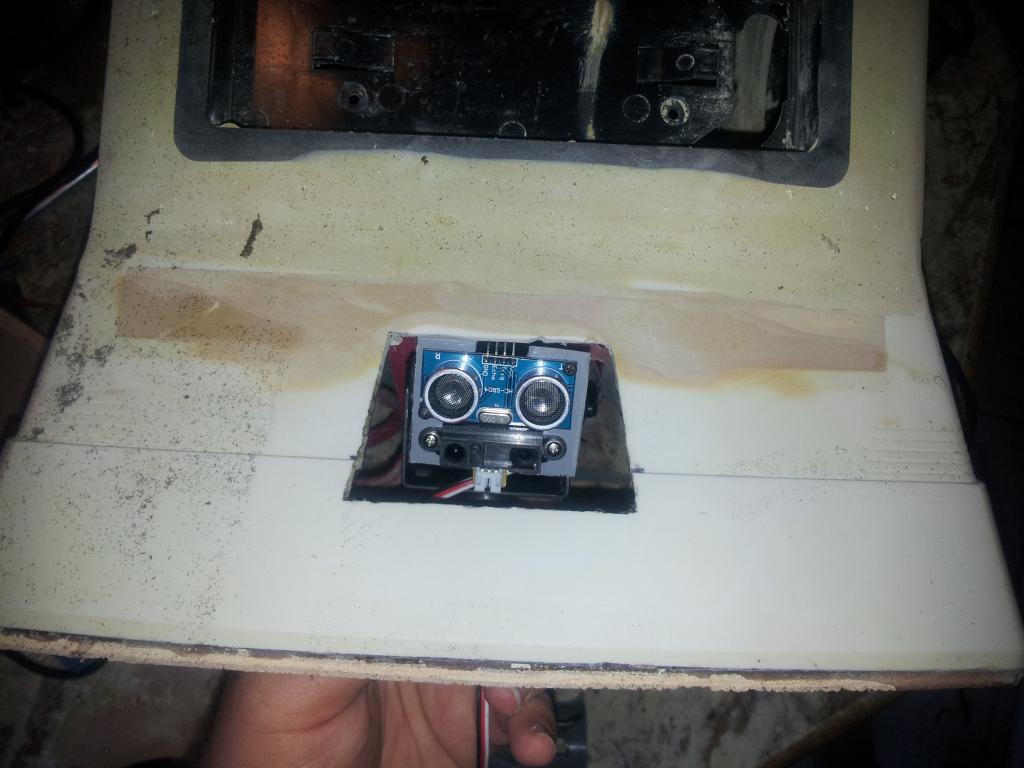
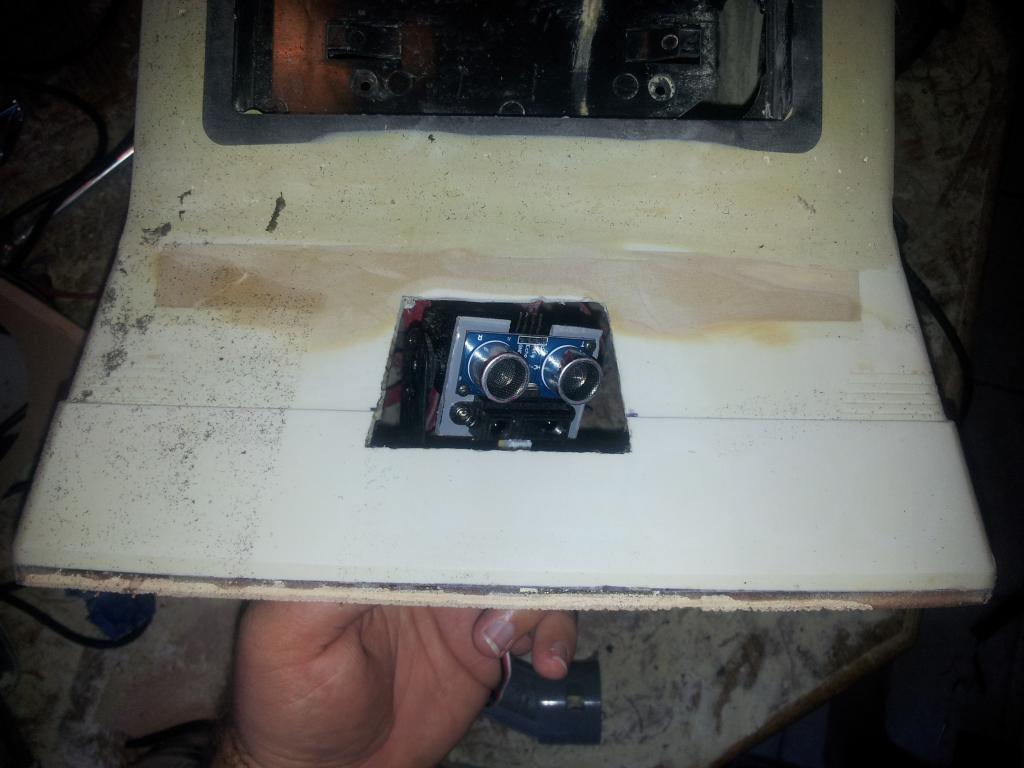
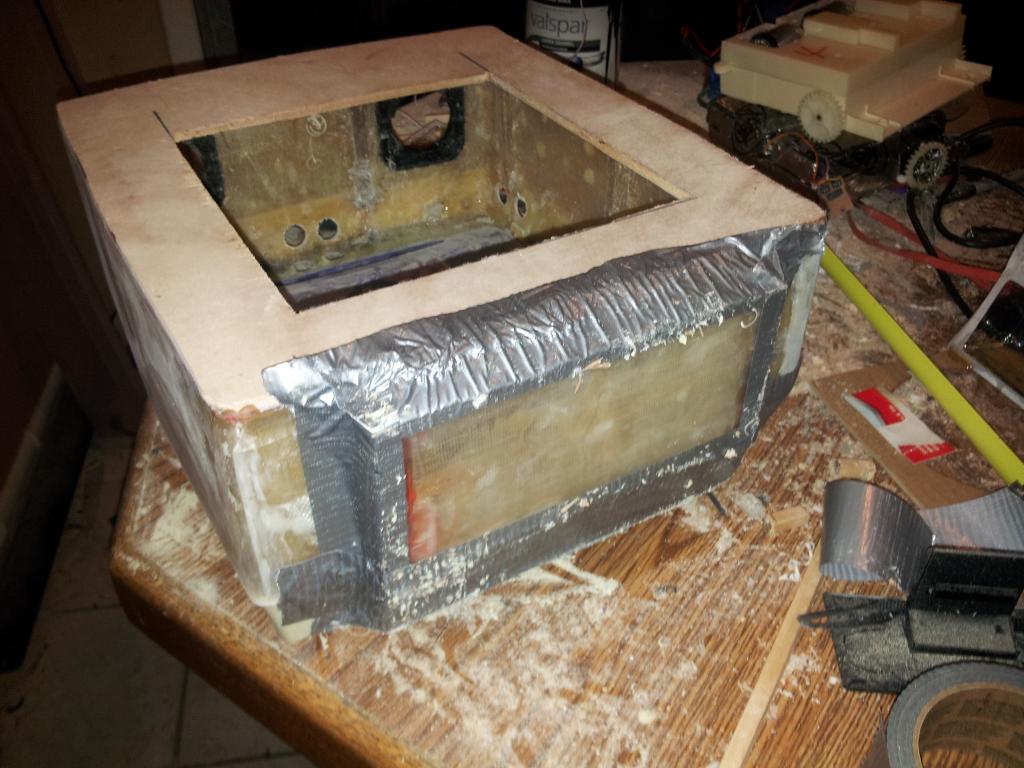
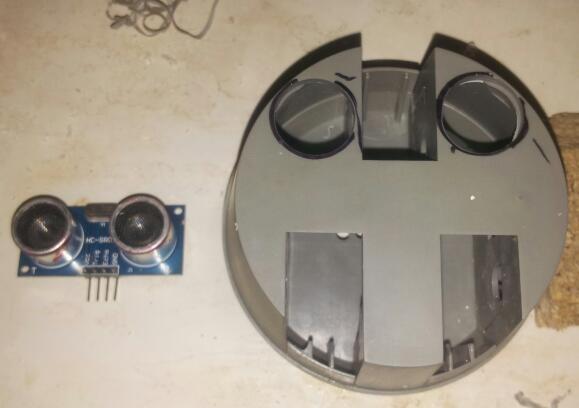
Youtube video testing the sonar and IR pan and tilt
https://m.youtube.com/watch?v=kbuQ-012bG4#/watch?v=kbuQ-012bG4
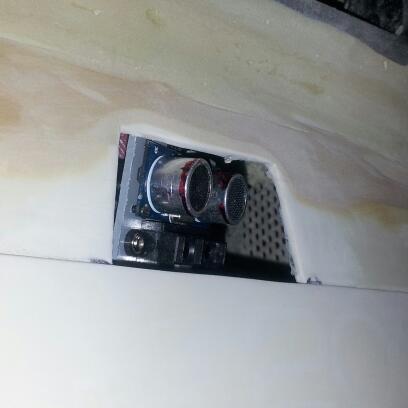
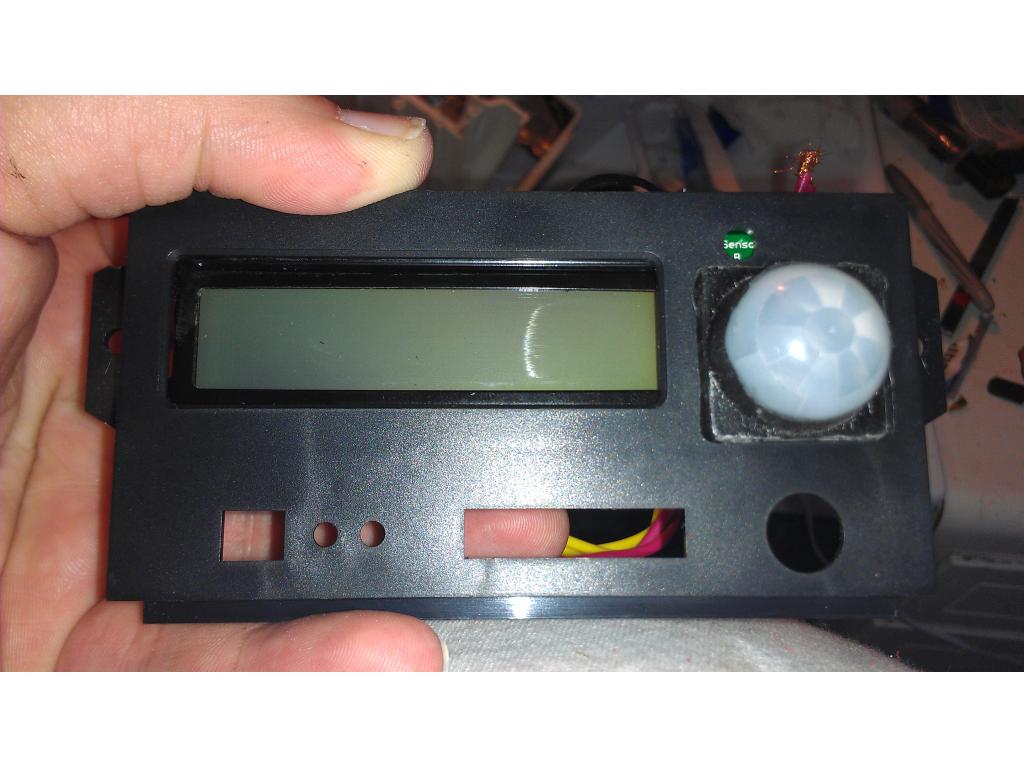
Looks like i need a bigger slot to see through!
Looking really good!
Thanks bud!
HI Josh
wow on the motor conversion very nice.
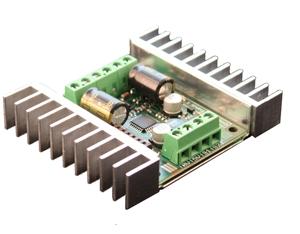
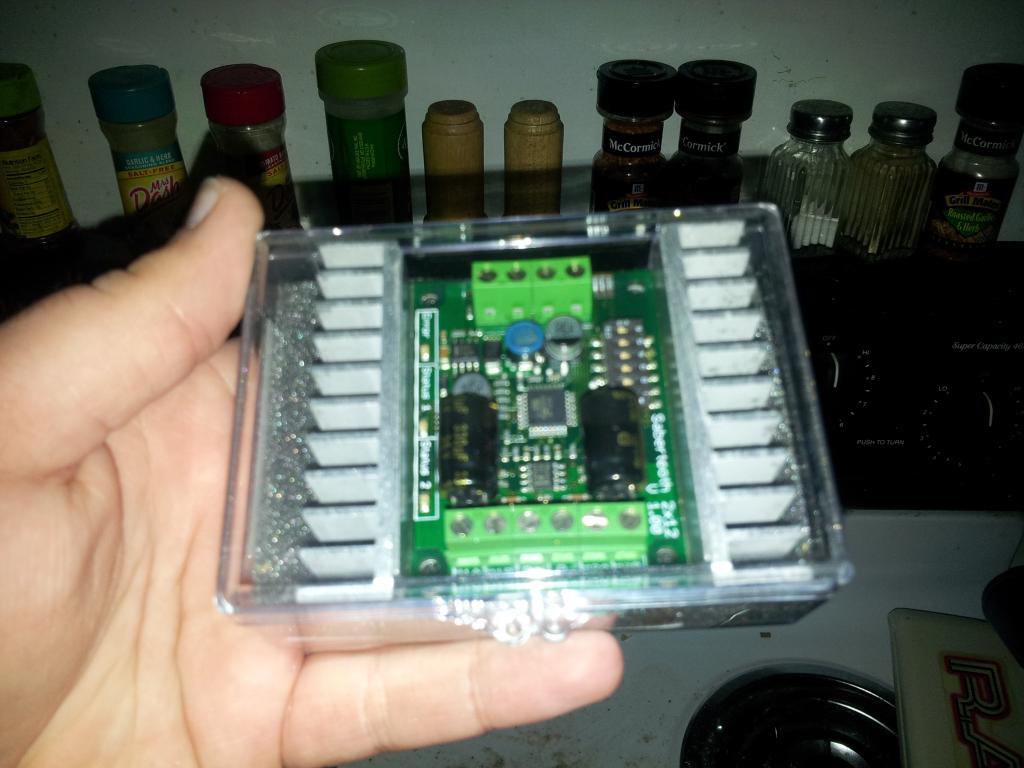
How did you get to try a new controler man , major score there m8
all Sabertooths have overload protection so use it with confidence .
Again great job josh .
PS go up a size on your motor cables , it will help with the cooling ( there is a pdf on there site somewhere ).
Steve_C.
JOSH how are going to cover it,cant use acrylic on the front like on IR sensors idea that will work it place a plastic on the sonar ,little longer and when is sweeps that plastic covers up the slots,very thin sheet of plastic this way it looks good and keeps the dust out
Hey Steve , i contacted them for information. They discontinued the controller i was thinking of but gave me the next step up for the same price =)
I will consider that robotmaker