


Robot Building Community
Share robot projects, ask ARC programming questions and learn from other builders. Browse tutorials, Robot Skills, example programs and community discussions.
Drive Real Robots, Anywhere
Remotely operate robots around the world or add live telepresence to your own build — straight from your browser.
Discover Exosphere
Robot Sticker
Autonomous AI
Autonomous AI robot skill with vision, speech, movement, animations, and self-directed task...
Azure Text To Speech
Azure Text-to-Speech for ARC: generate natural-sounding robot speech with Microsoft Azure voices,...
Exosphere
Telepresence and remote control for any robot with human-assisted tasks, video, audio, and AI...
Azure Speech Synthes…
Microsoft Azure neural text-to-speech for ARCx scripts and skills, with multilingual voices, SSML...
Rtk Gps
RTK GPS rover/base skill with NTRIP corrections, cm-level pose, heading support, map fusion, and NMS...
Outdoor Navigator
GPS-driven outdoor robot navigation with satellite maps, saved waypoints, zones, no-go areas,...
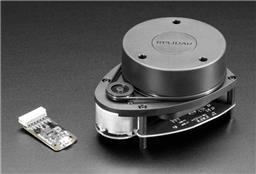
Slamtec Lidar driver for ARC; scans 360° and publishes distance data to NMS for mapping, obstacle avoidance, and navigation.
Continues Read Of Ir Sensor
Im a little confused here. I'm simply trying to read the value coming from my IR sensor (one of the Sharp IR ones). The script I wrote should should be a simple loop and display the value, can continue to display the value until I tell it to stop. goto(sensor) :sensor $IRSensor = GetADC(ADC4) # Sharp IR Sensor print($IRSensor) sleep(1000) Return()... 10
 4 k
Init Start
in the init i can see the servo's d1 and d0 are set slower. i try to ad servo id d2 and d3/d7/d4 but they dont slow down. when jd goes in to calibrate postion it go's so almost violently fast. can this be changed ? thanks anyone
3
3 k

EZ-Robot Inventor Builds A $50,000 Scarlett Johansson Robot
Ricky Ma built a robot version of Scarlett Johansson, spending over $50,000 and 18 months to complete...
0
794
Switching Polarity To A Dc Motor
Hello everyone; I'm assume it is possible, I need to have the EZ-b control a dc motor to the left and to the right, by switching polarity, between neg and pos,,,is that easy to do?
10
4 k

Gripper Servo Foam Inserts?
Hello, I purchased a Gripper Servo and have it on my robot and set up but have some questions: The foam pieces that are included inside the gripper claws, are they...
2
3 k
Aceboss's I'd Like To Explore Robotic Ap
Assist visually impaired: robot reads ebooks, web and news, tells time/weather, searches internet, sorts banknotes/socks/meds, self-docks to charge.
0
3 k
Wait For Color, Wait For Face & Wait For Glyph In ARC Mobile?
Hello, I was using roboscratch in my mobile application and noticed the Wait for Color, Wait for Face, Wait for Glyph don't appear to work in mobile ARC application. Seems I read in one of the threads that Wait for Color works on Mobile Device using roboscratch but not Wait for Face, or Wait for Glyph detection. Am I correct or all wet? Seems I...
14
6 k
Windows Release 2016.04.28.00
Lower DAC audio noise after playback, adjust V4 Mini prebuffer, improve auto-position servo controls and smooth video buffering to reduce lag.
4
5 k

Digital Ports Voltage Output
Hello, We have been having issues with servo burnout over the last year with our original v4 EZB Robots. I have been spending a lot of my time researching and...
13
4 k
Taco's A Robot That Can Understand Co
Voice-controlled autonomous pet robot that understands commands, moves independently, and provides companionship for families unable to get a real pet
0
2 k
Dynamixel Mx-64T
Need help again with dynamixel servos! I was finally able to get all of my ax12a servos working. Now onto my elbow joints which use the mx-64t dynamixel servo which is ttl just like the ax12a. According to all information I find the servos can be wired together on the same bus. However I cannot communicate with it at all thru ARC. I have a feeling...
9
4 k
Jd Camera On Remote
had some fun this morning.not only did i find an error and solved . and made the camera on remote. you will recognize the music,but for sabbam reason i cant play it in full.
0
3 k