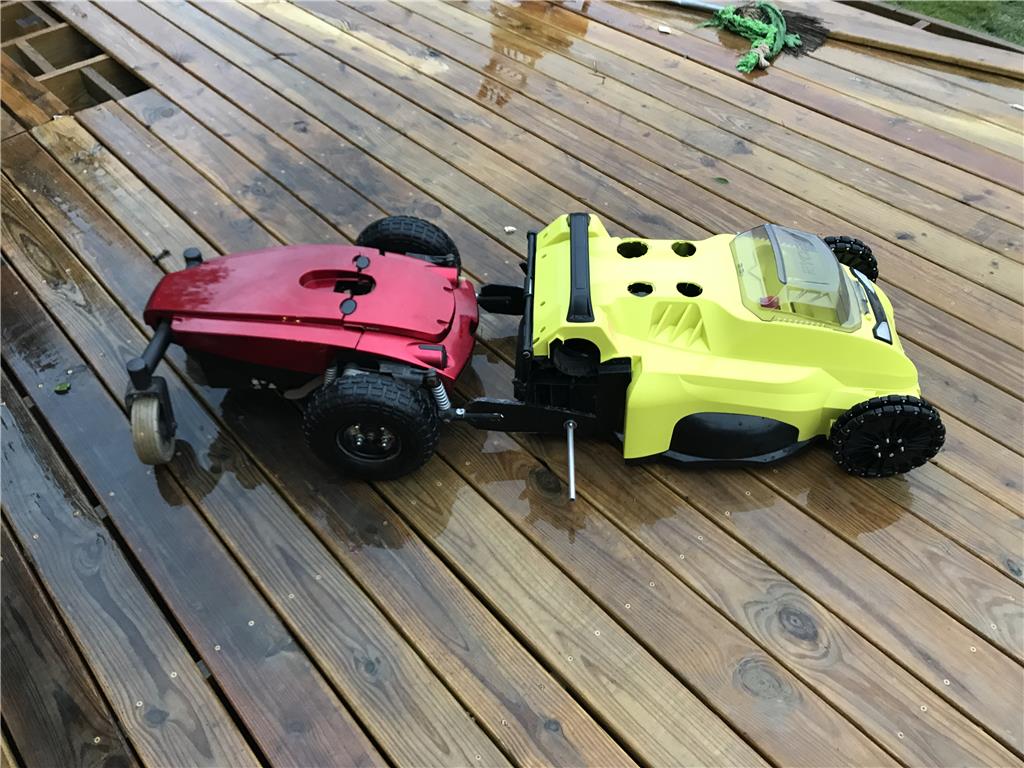
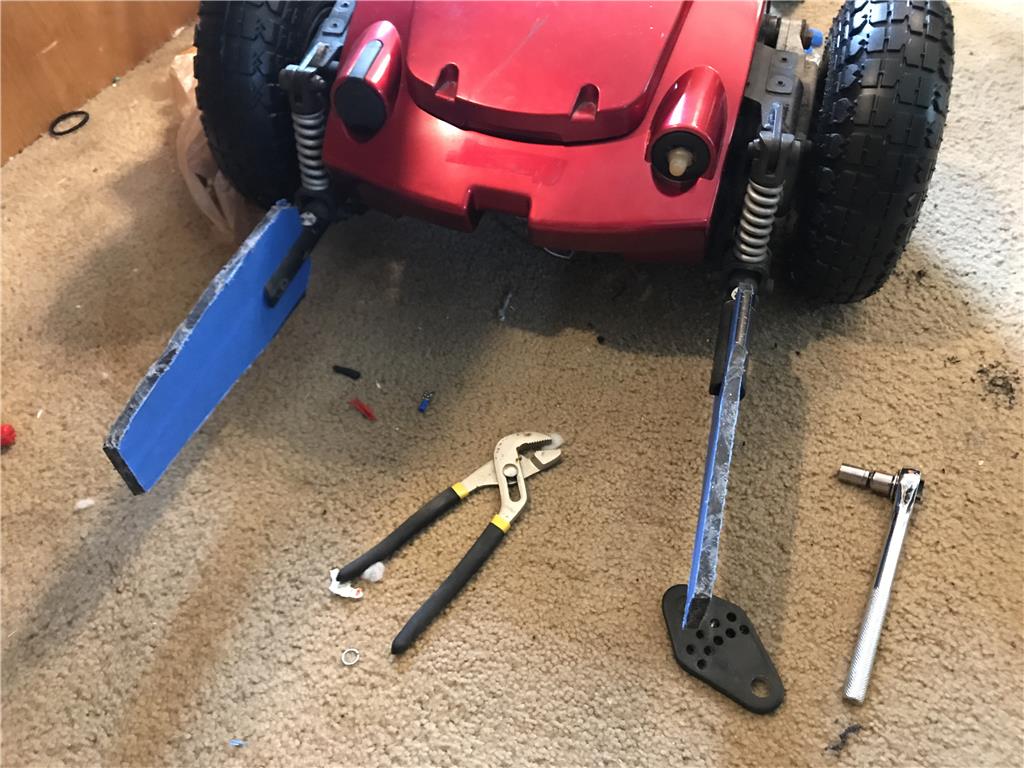
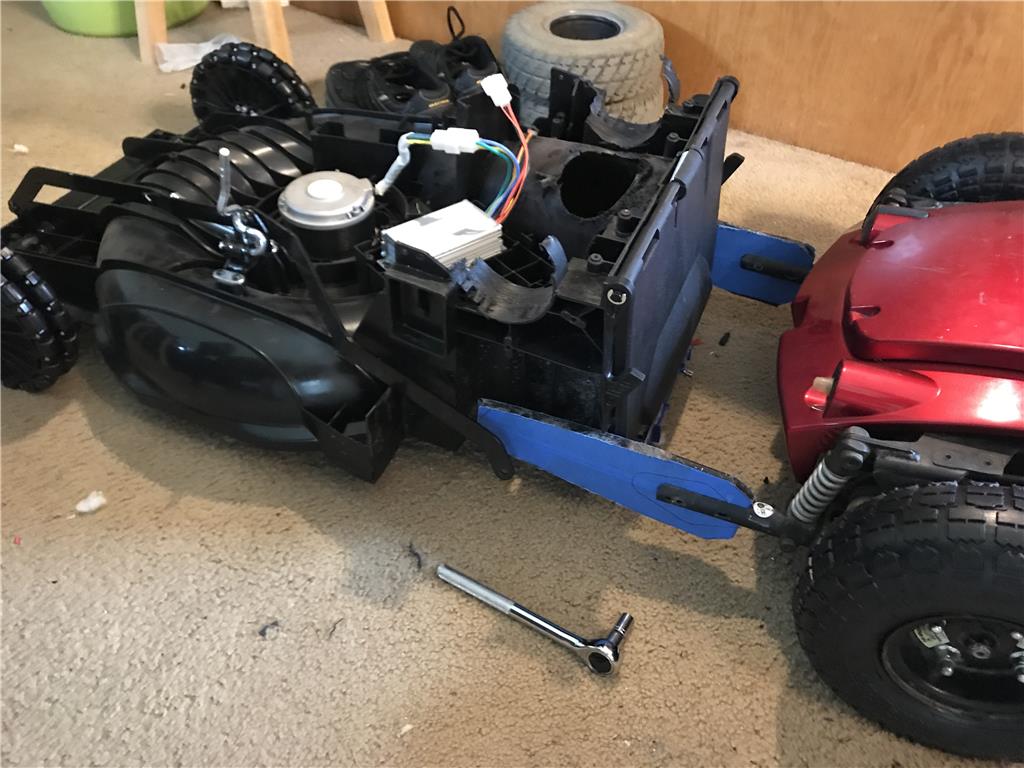
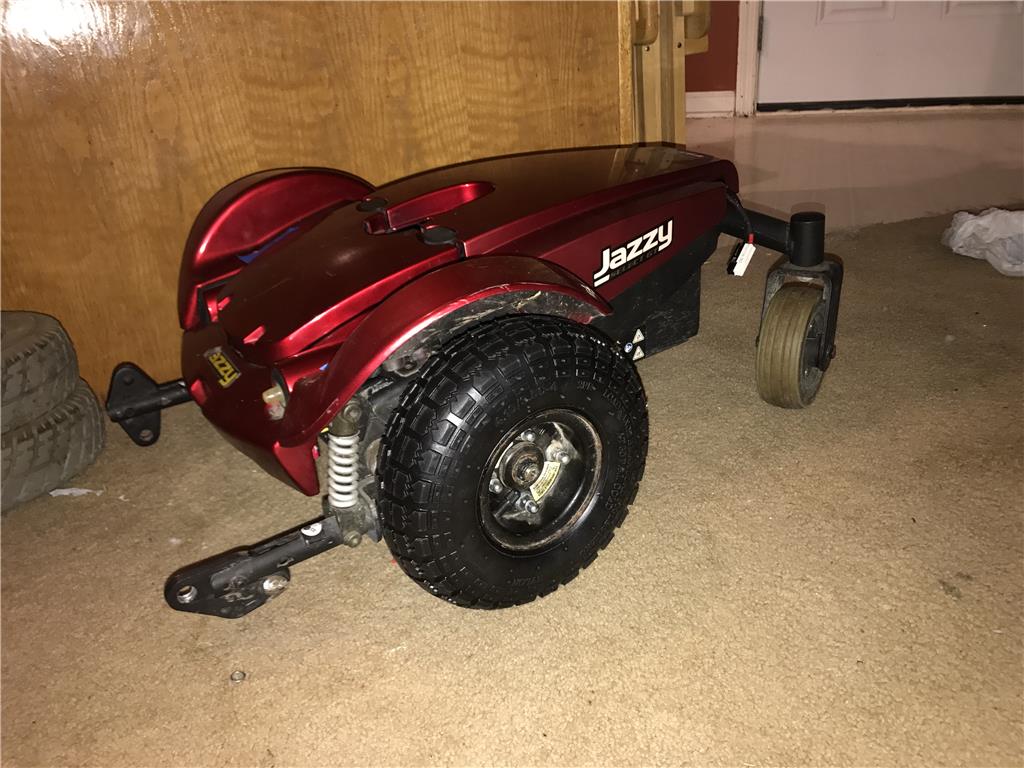
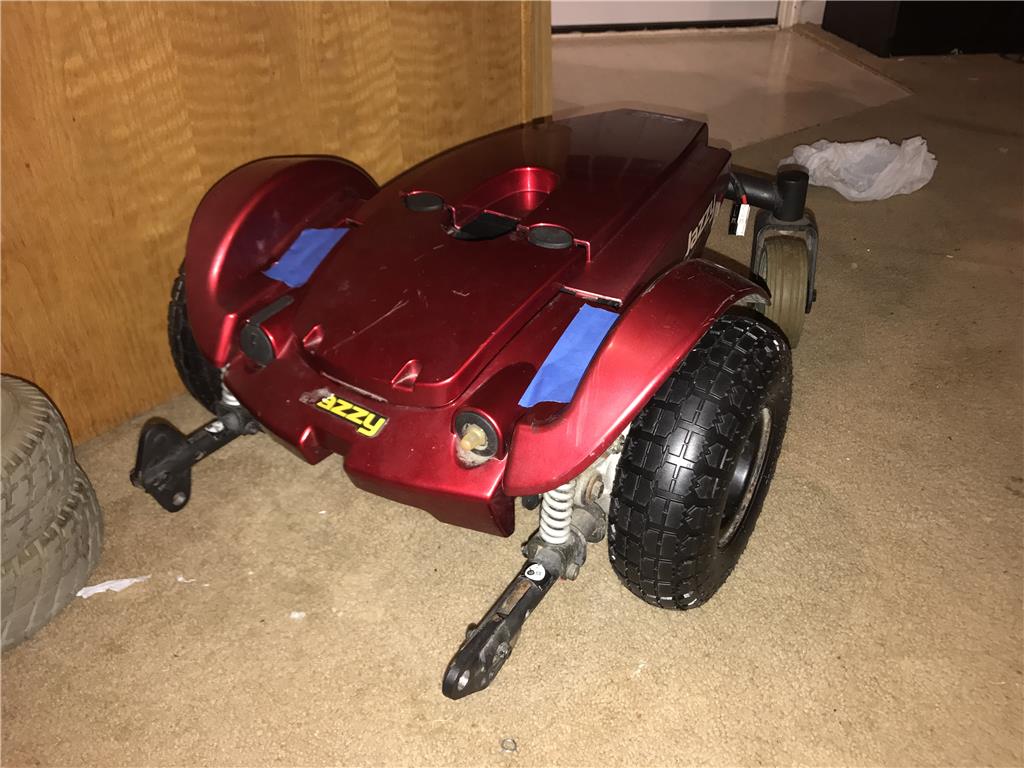
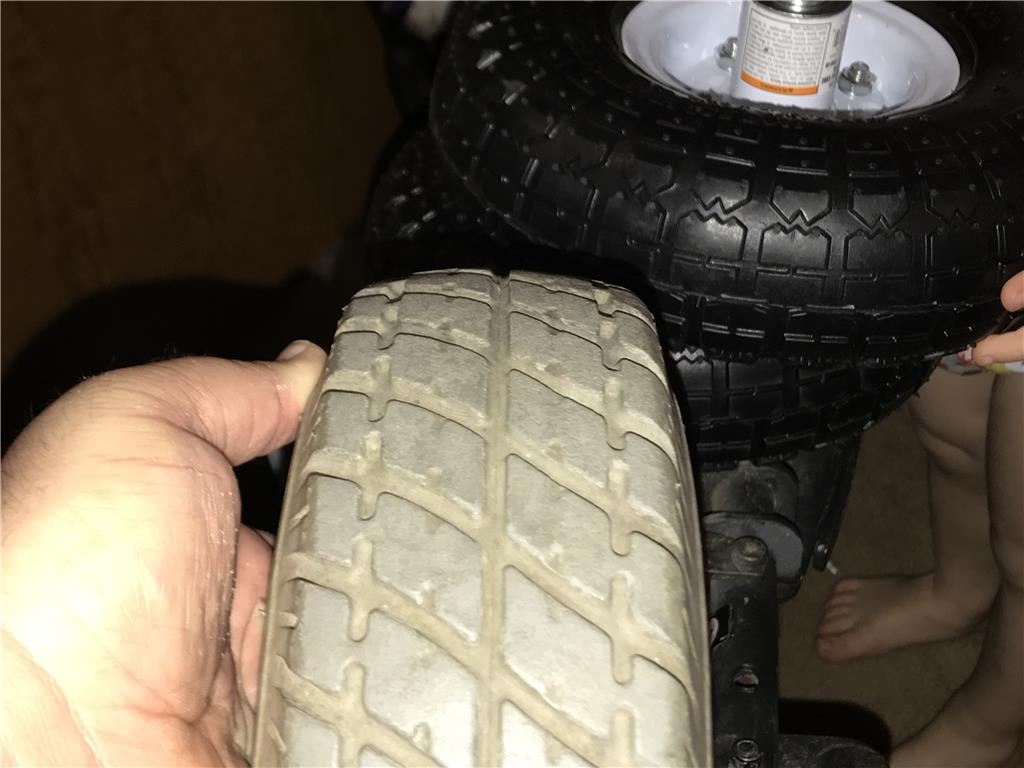
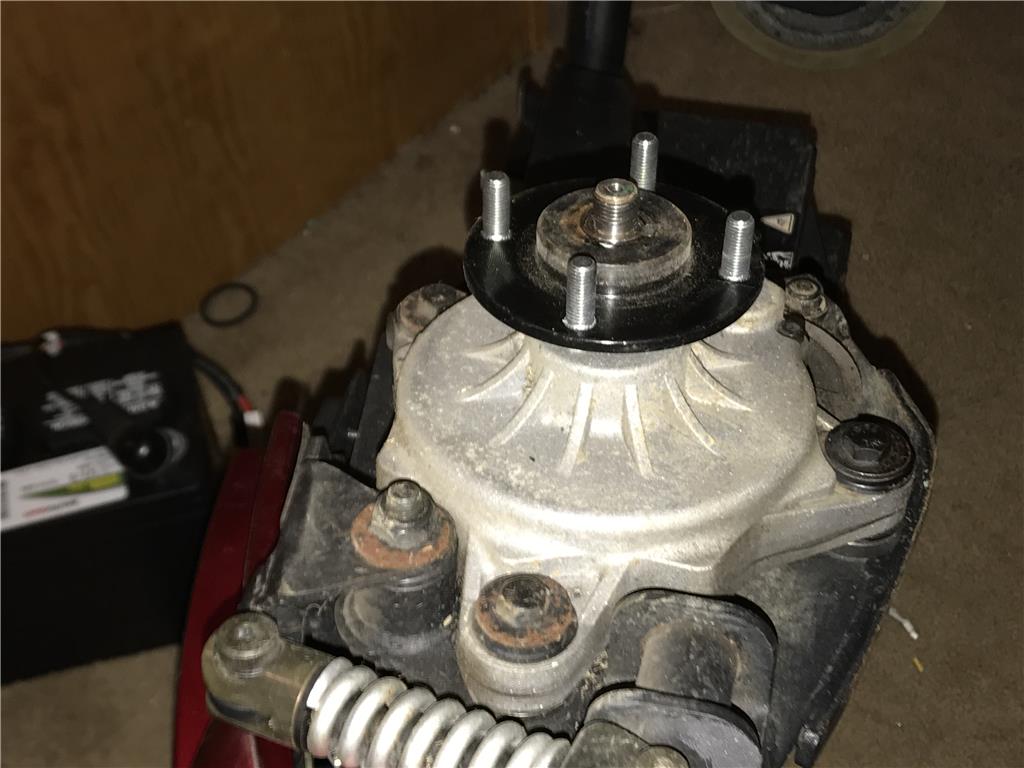
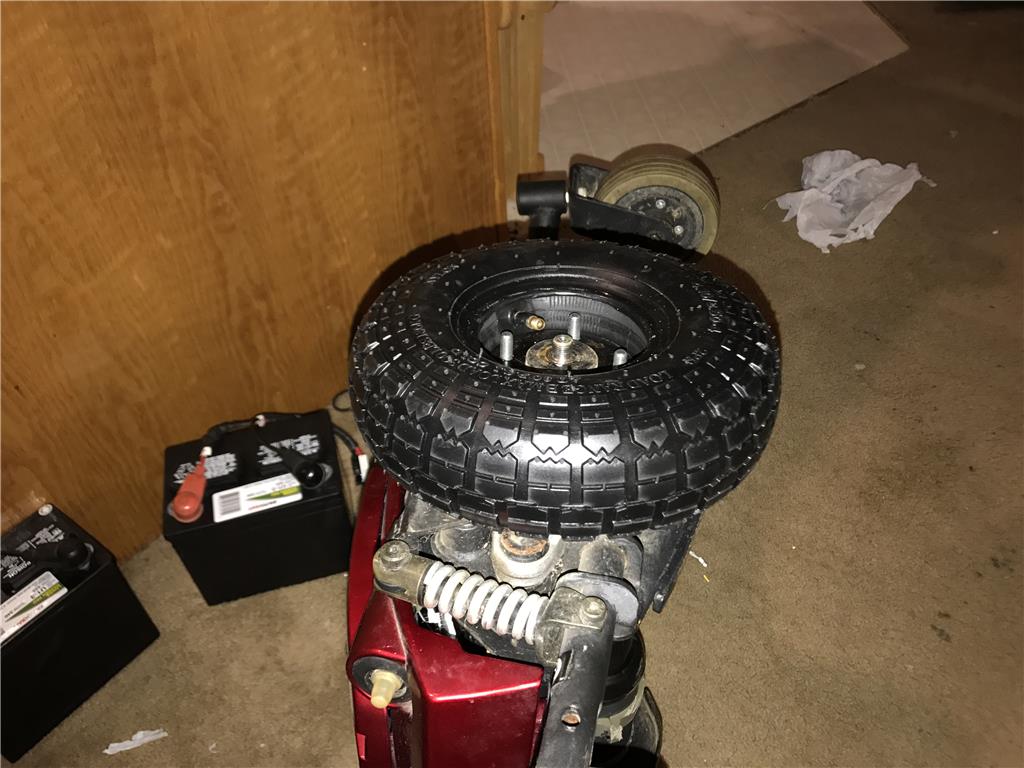
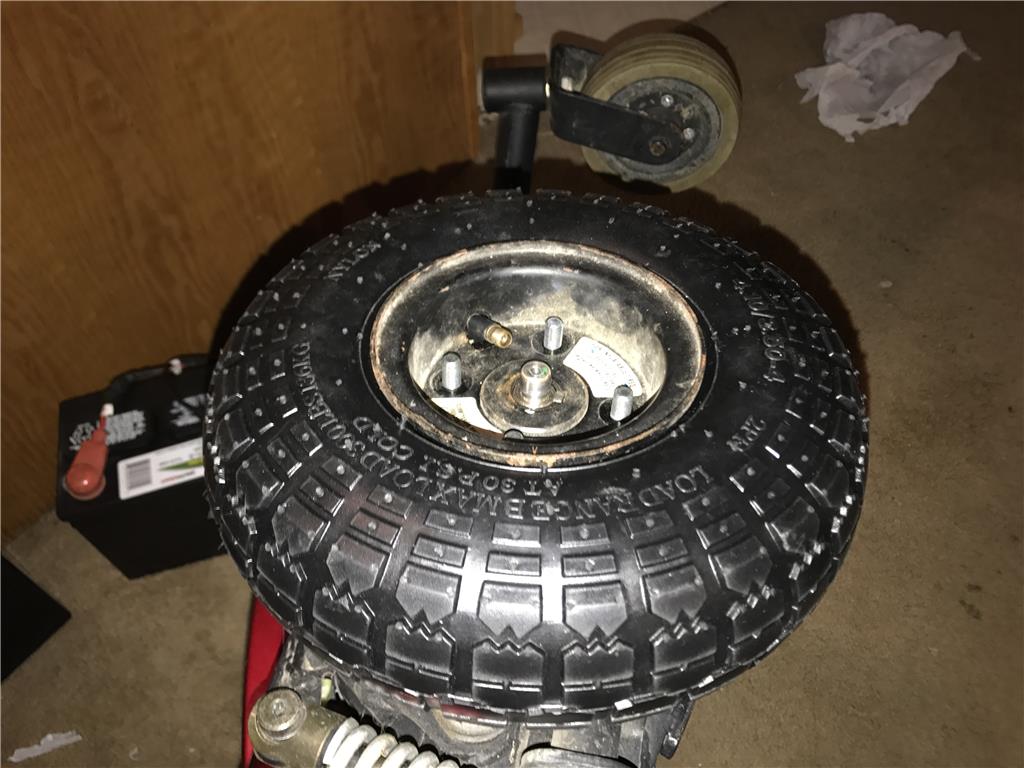
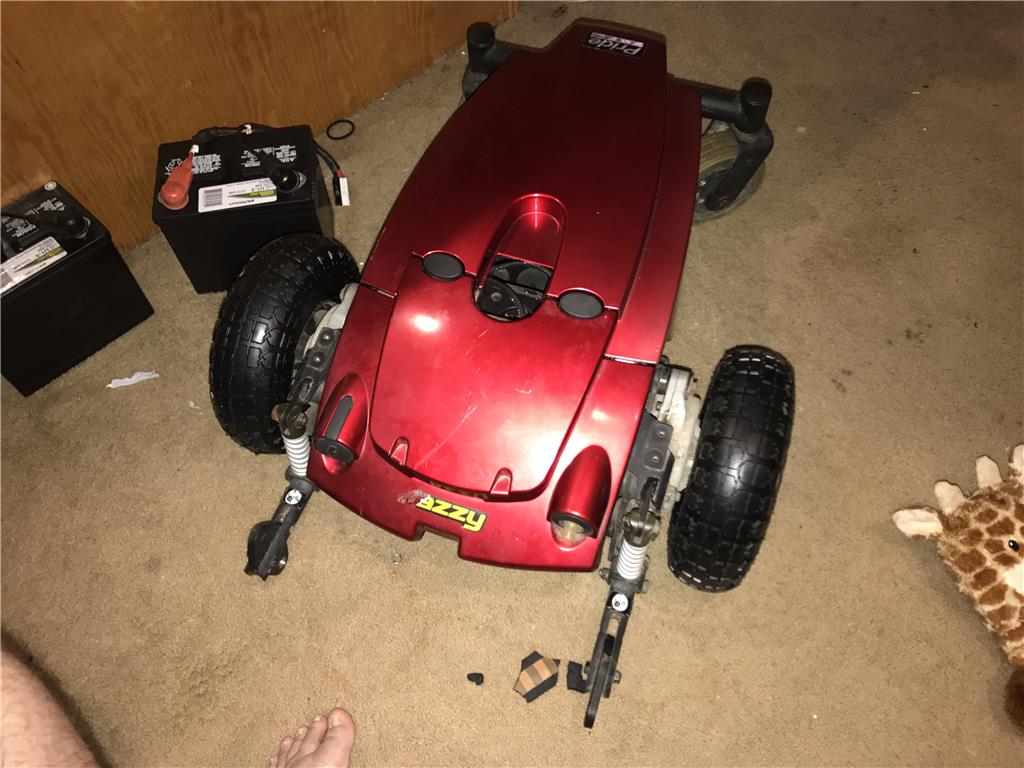
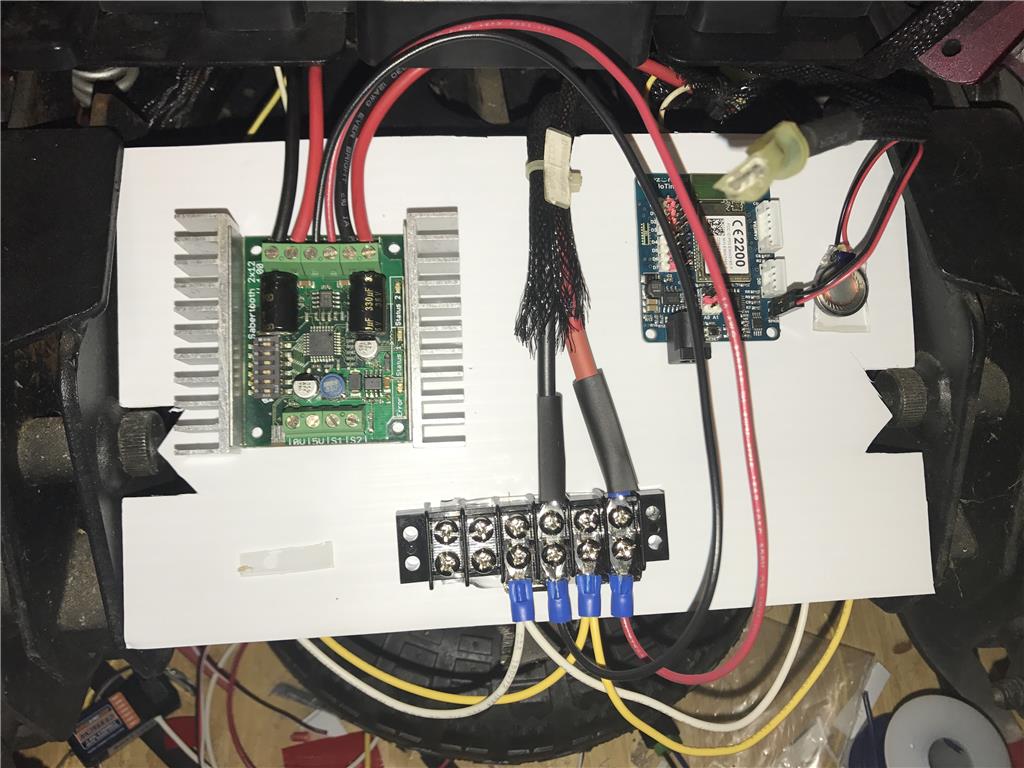
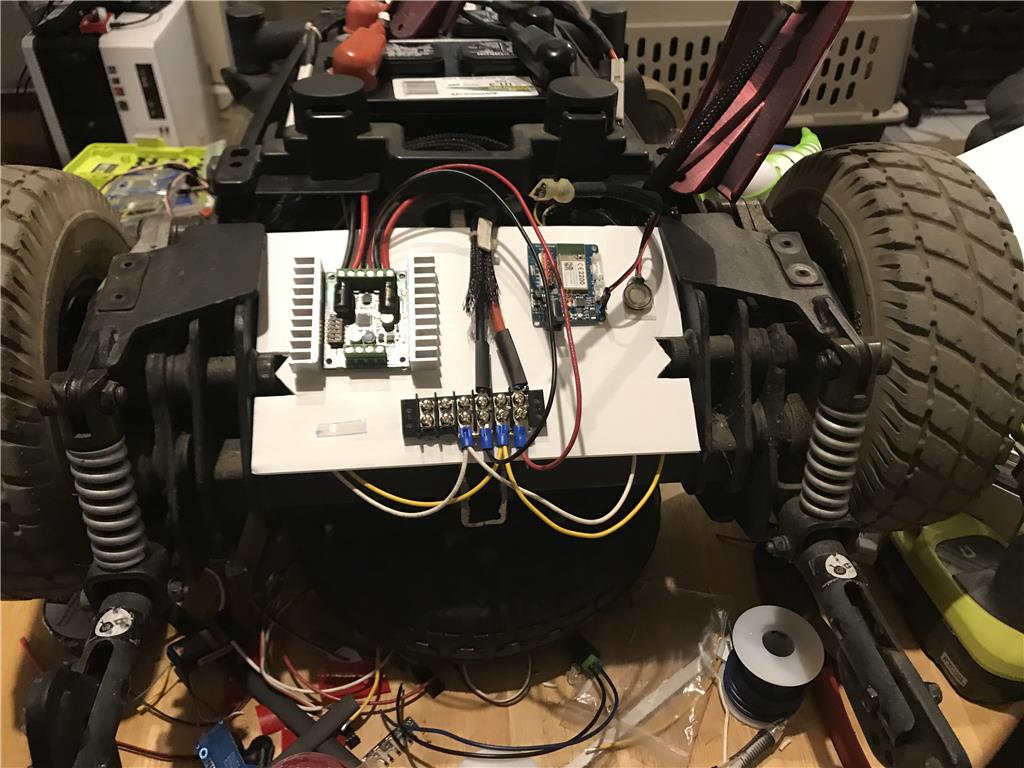
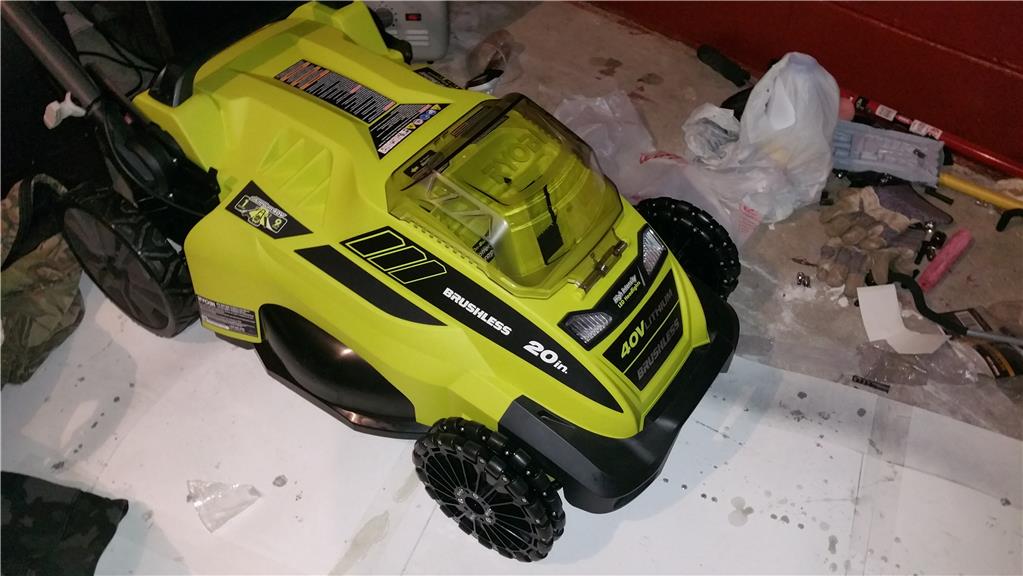
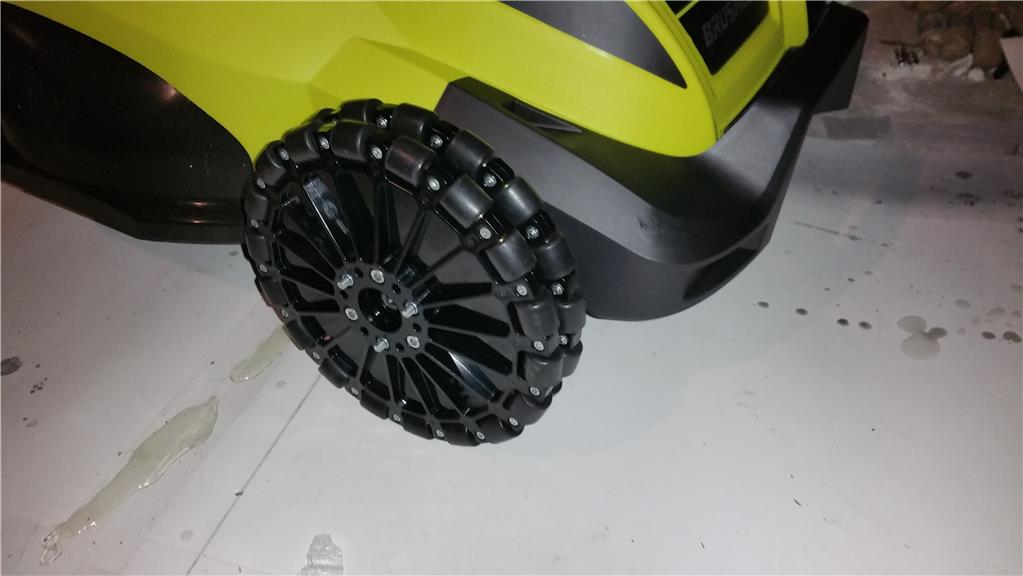
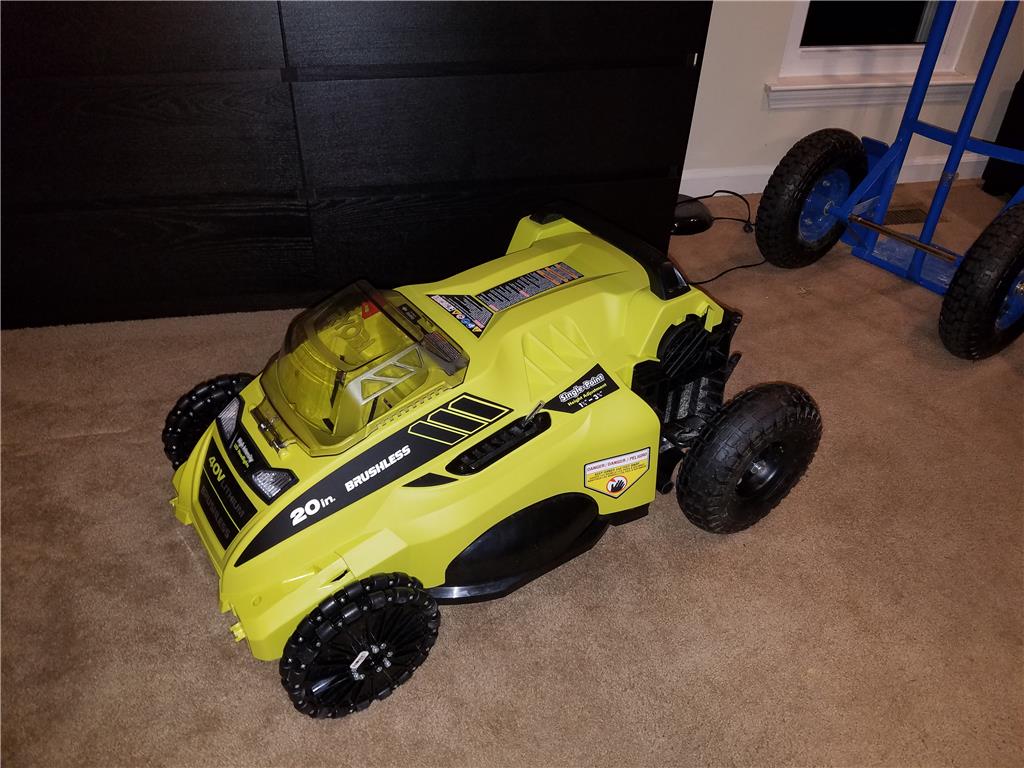
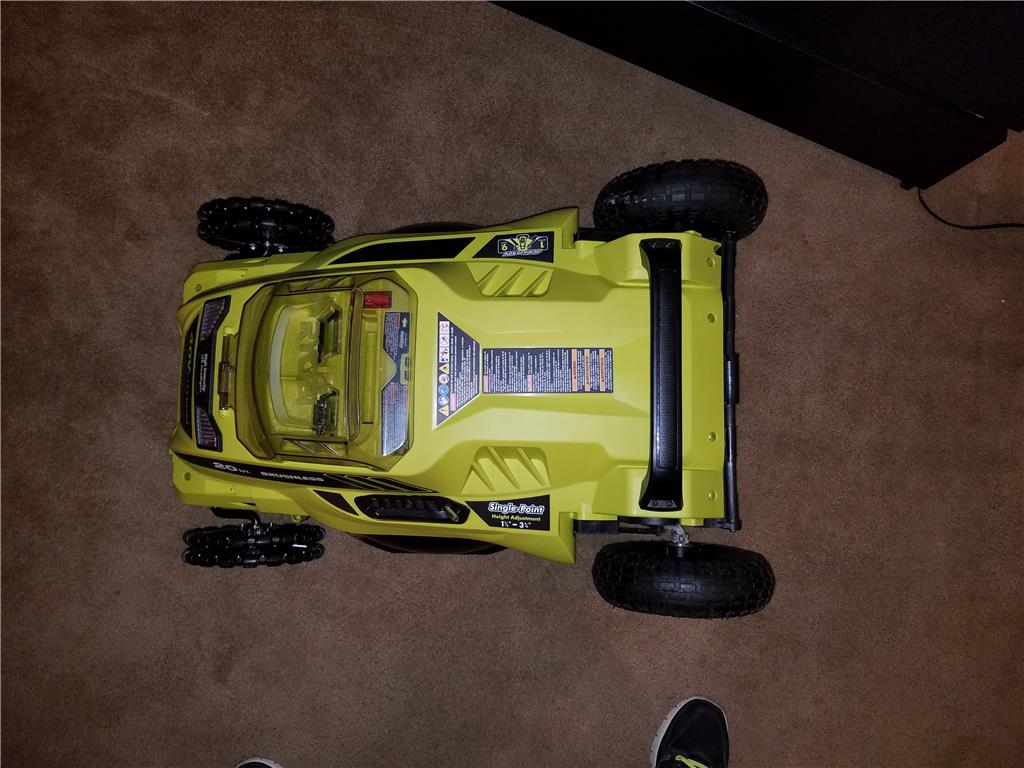
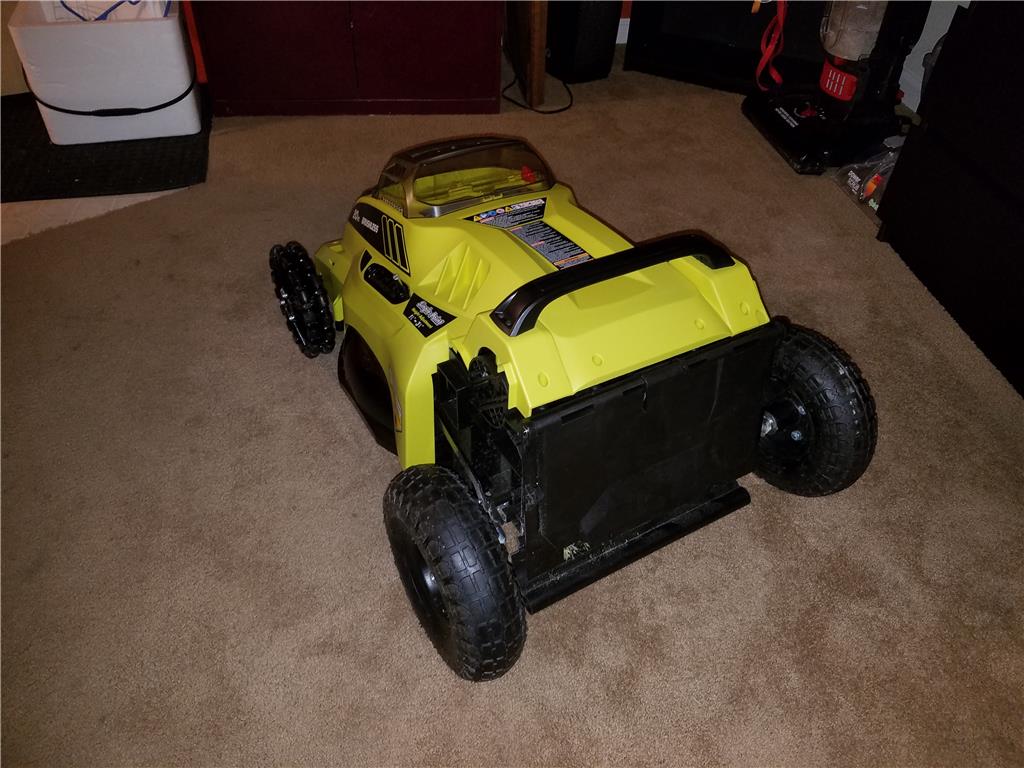
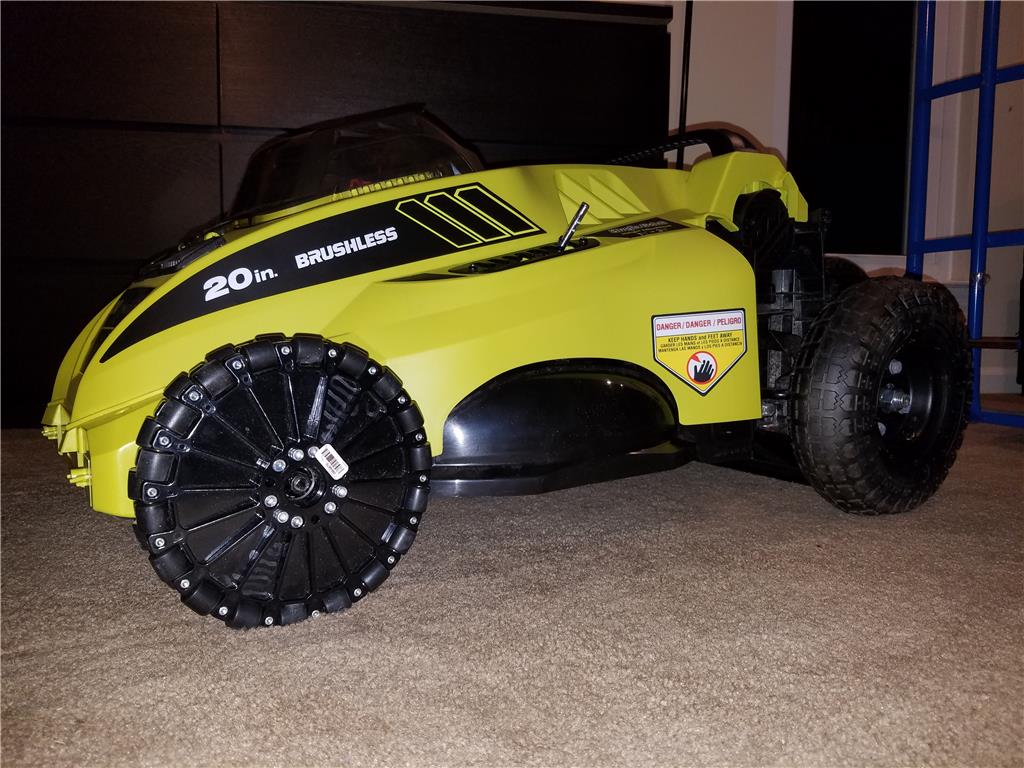

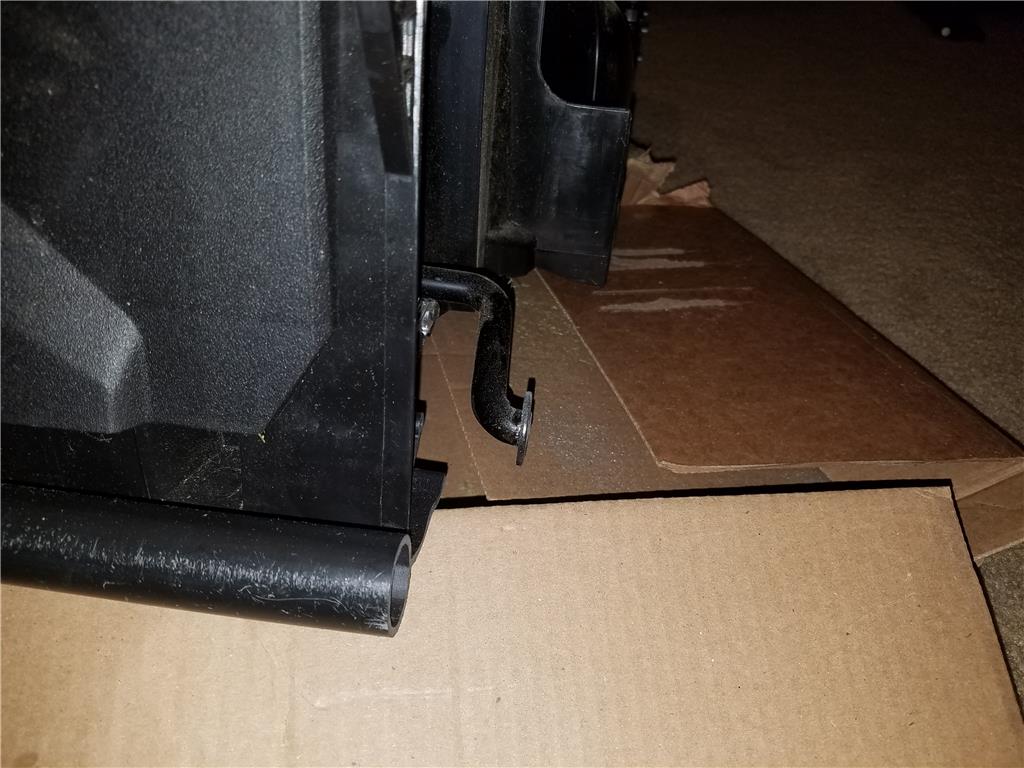
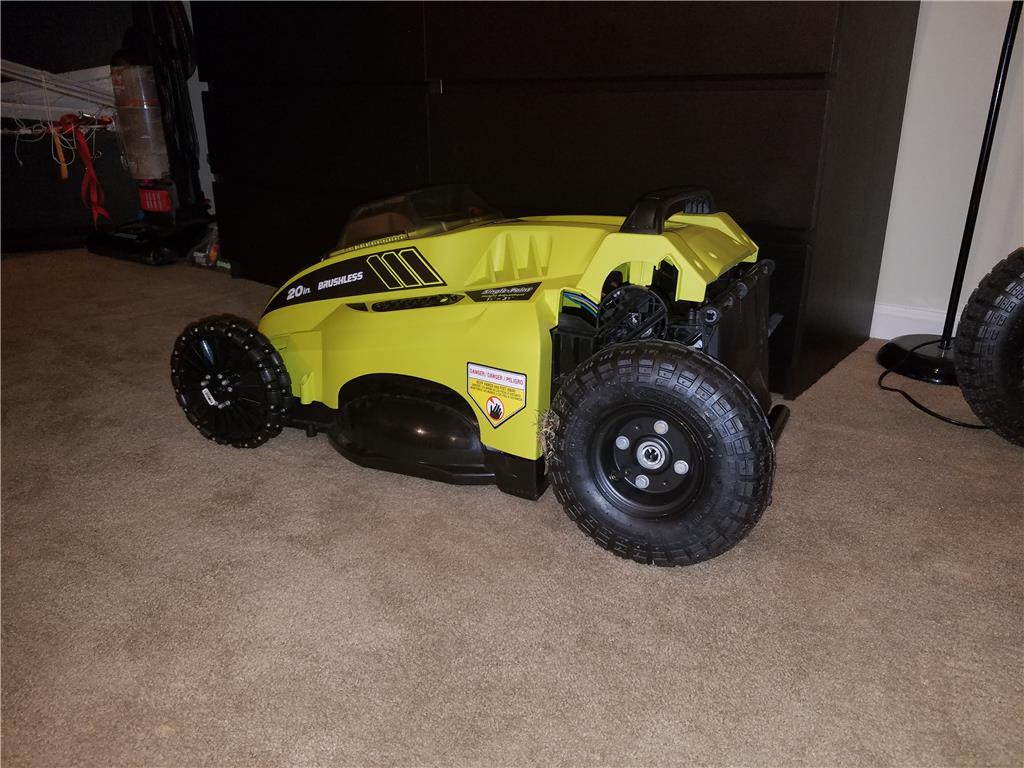
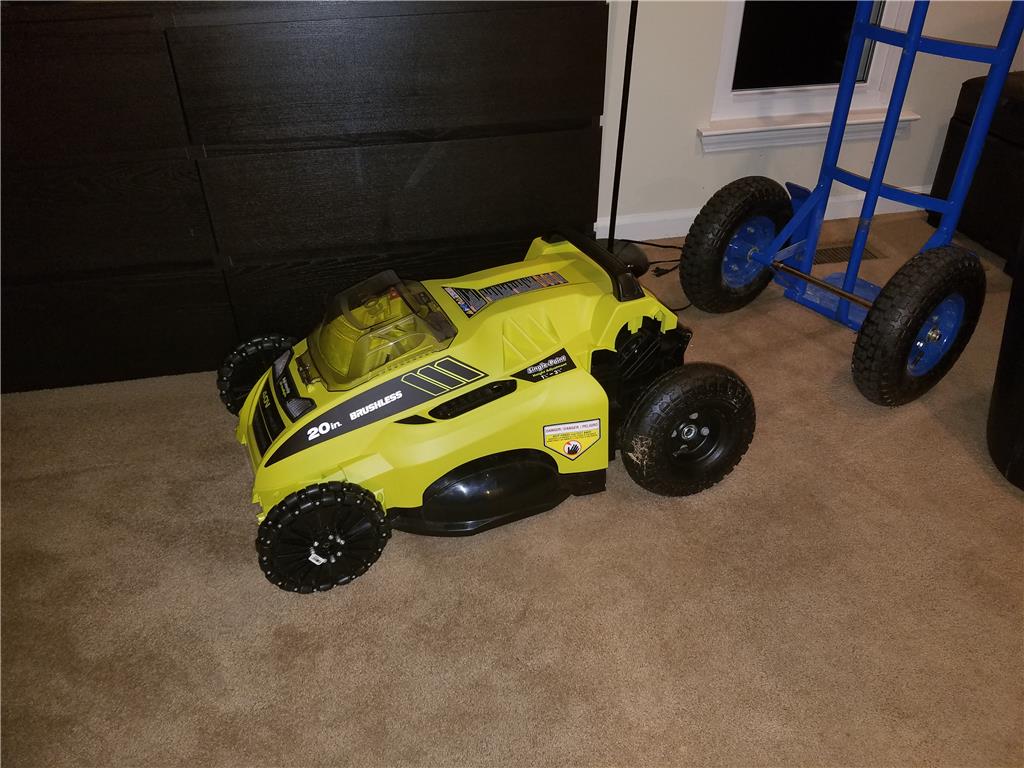
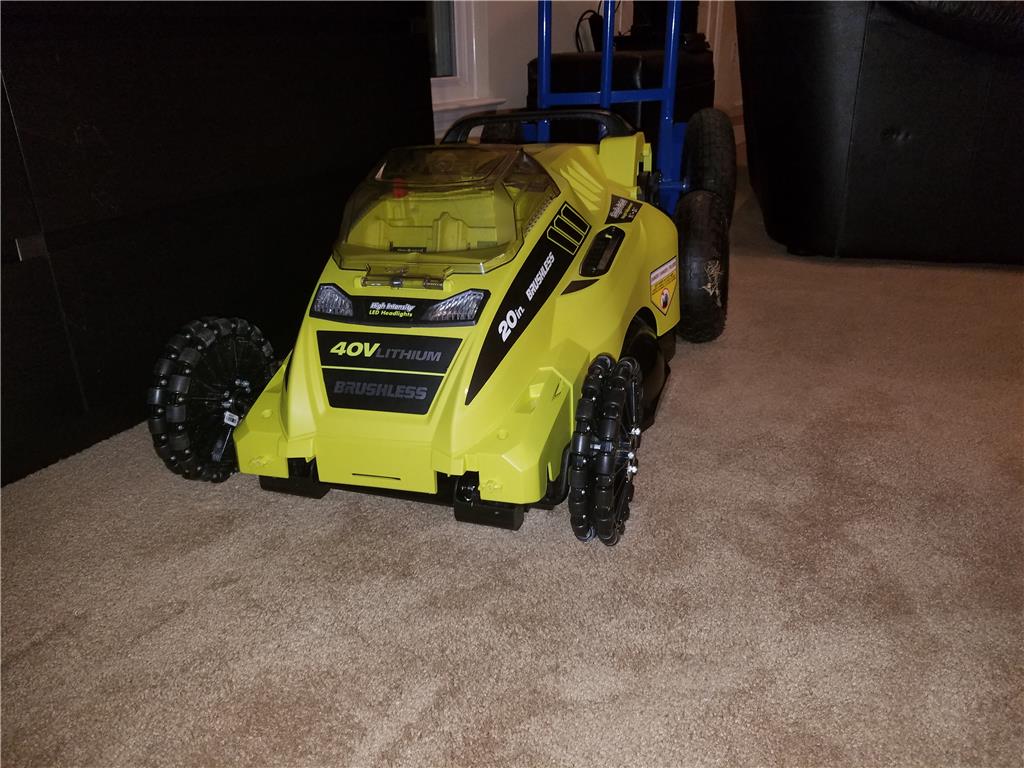
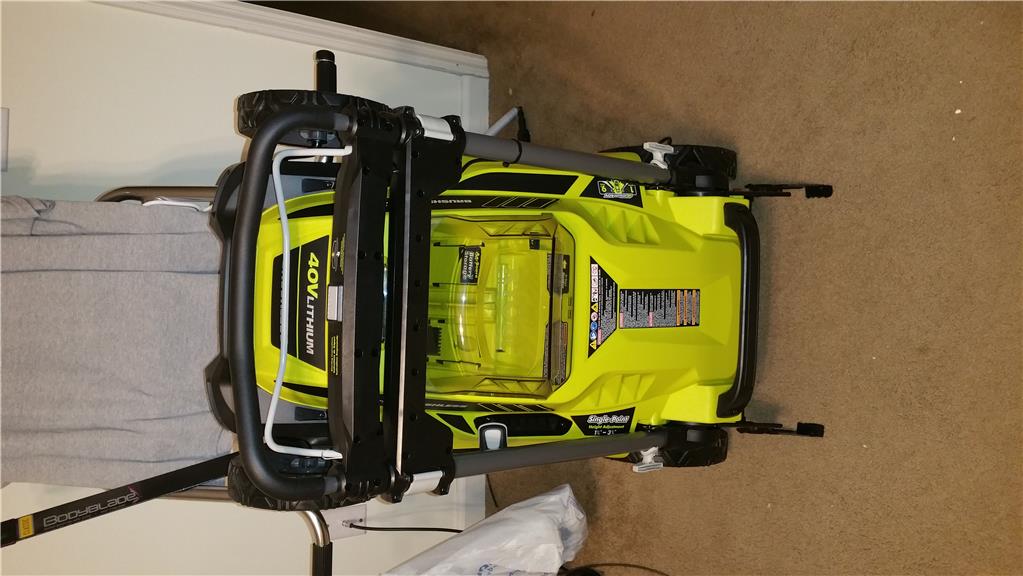
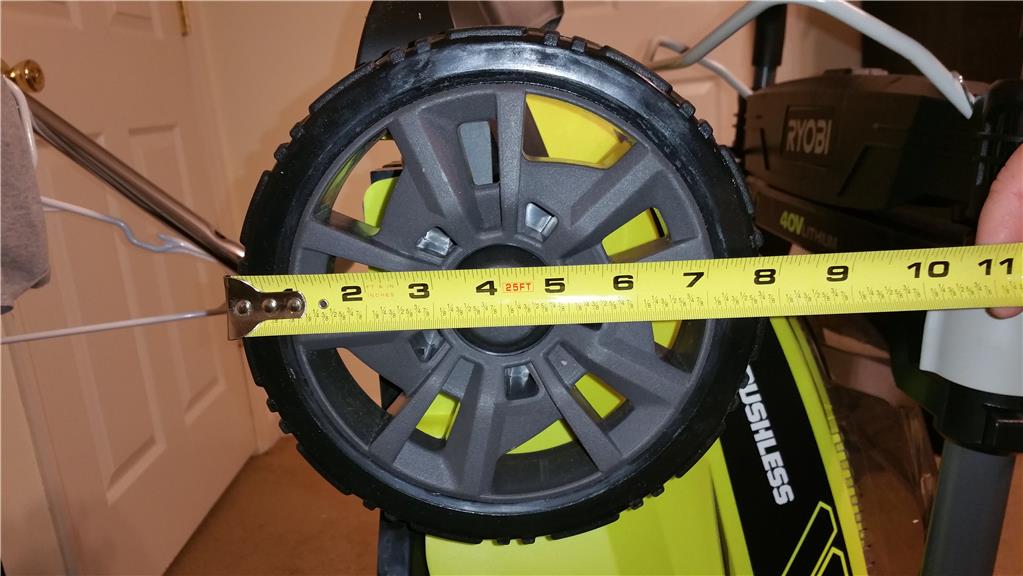
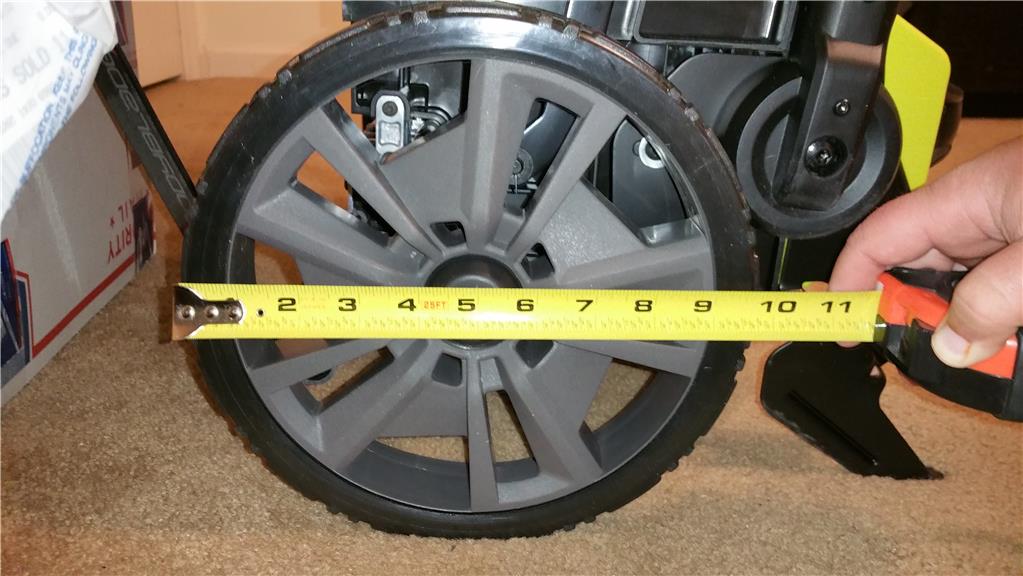


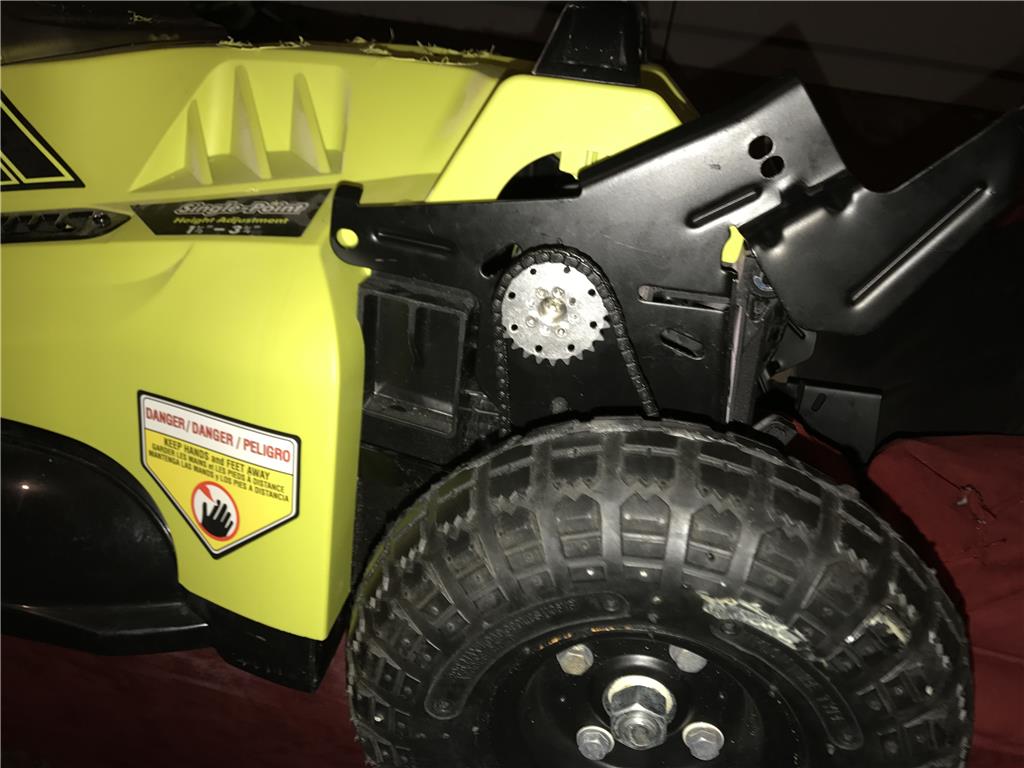
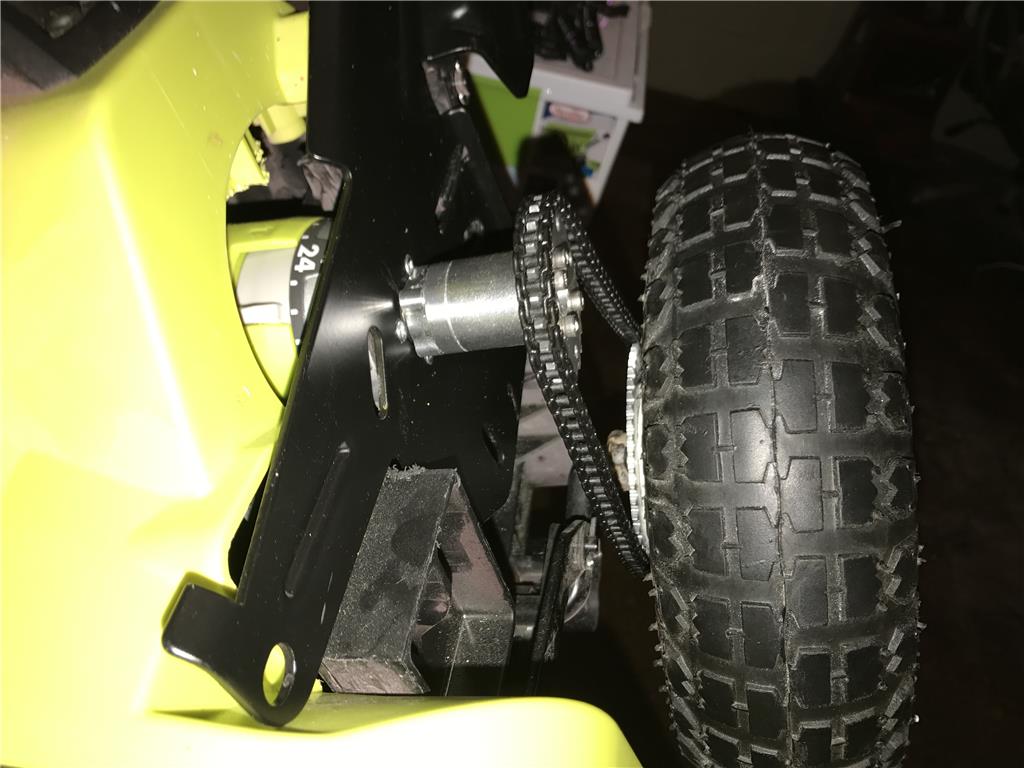
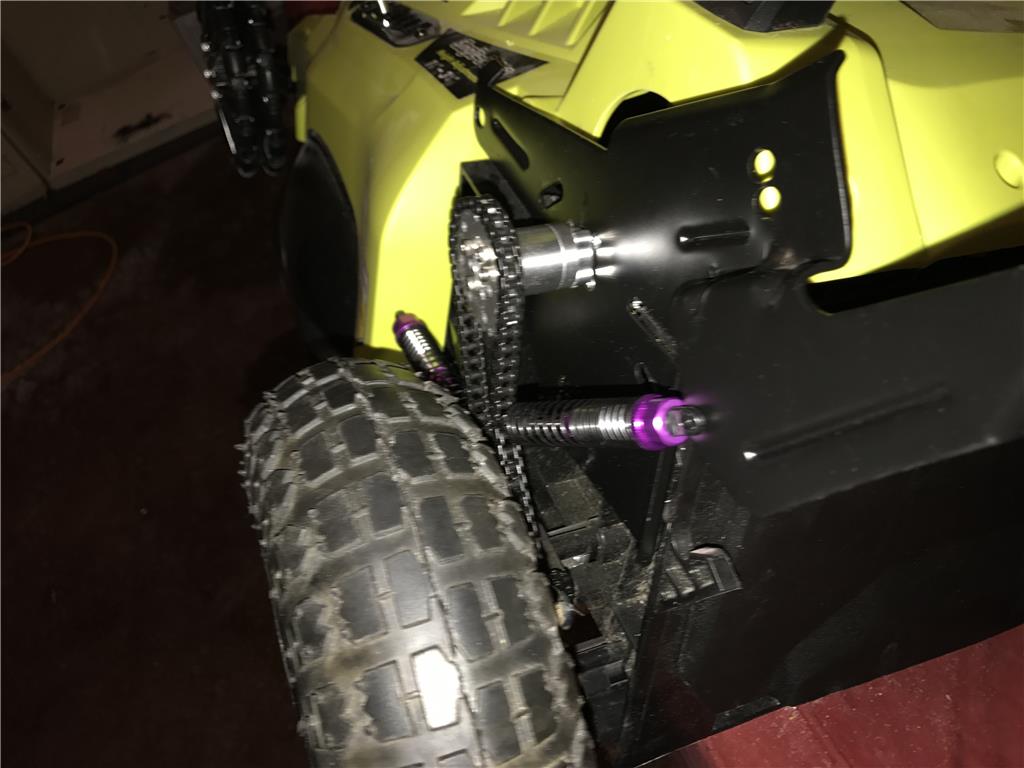
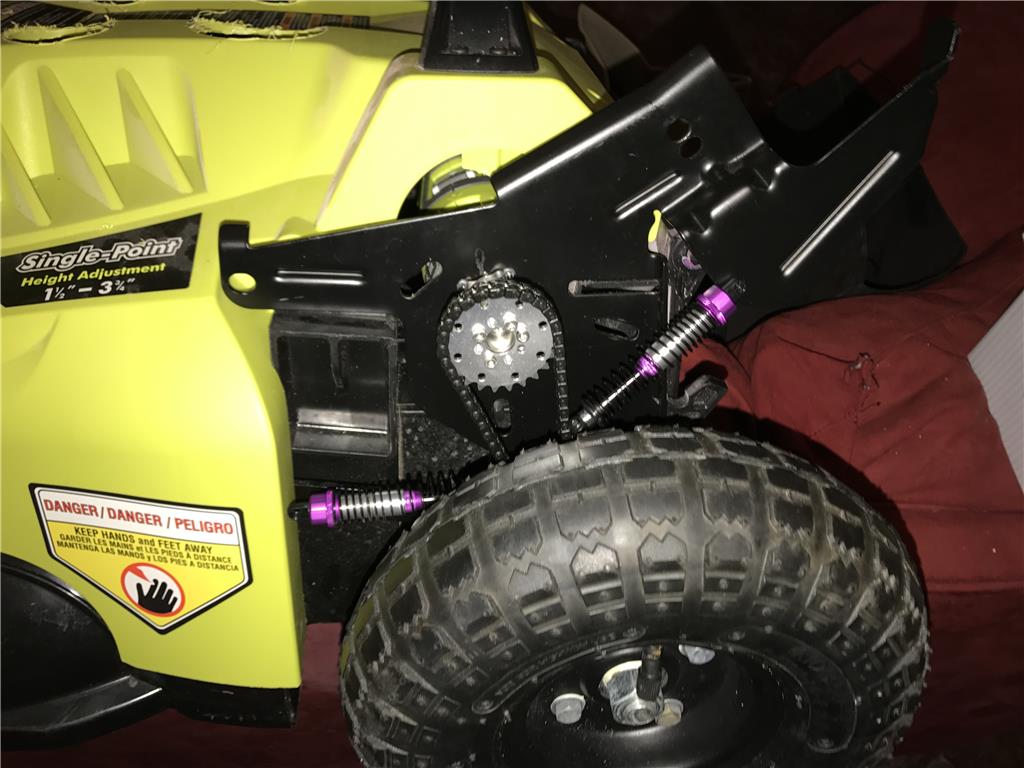
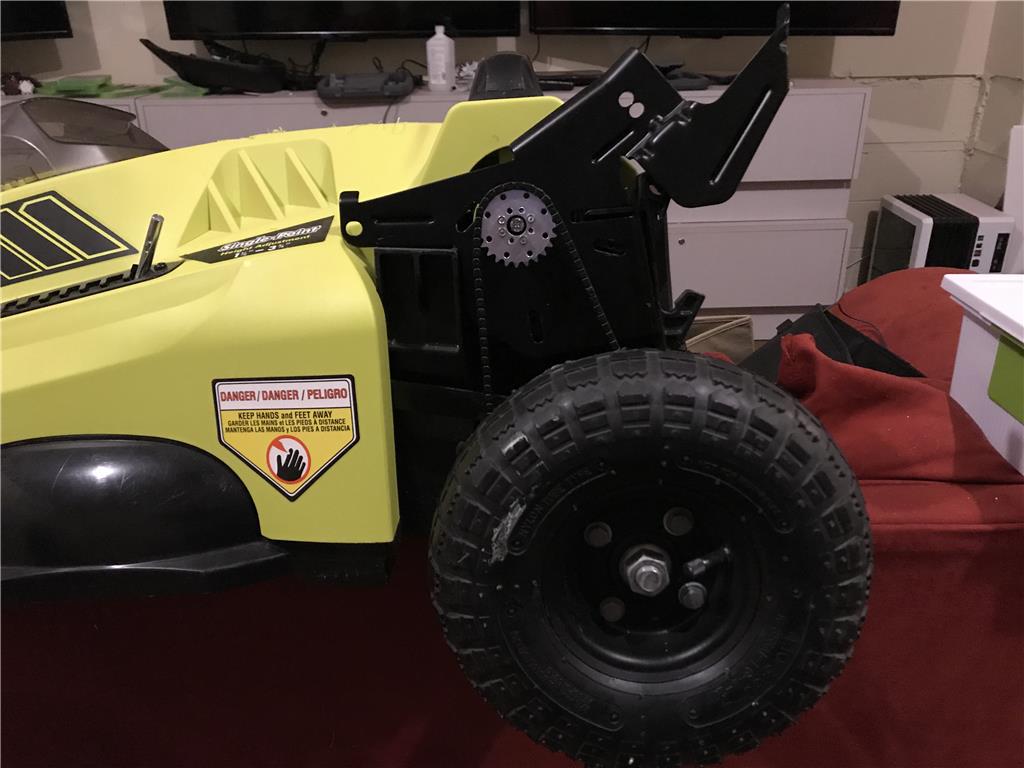
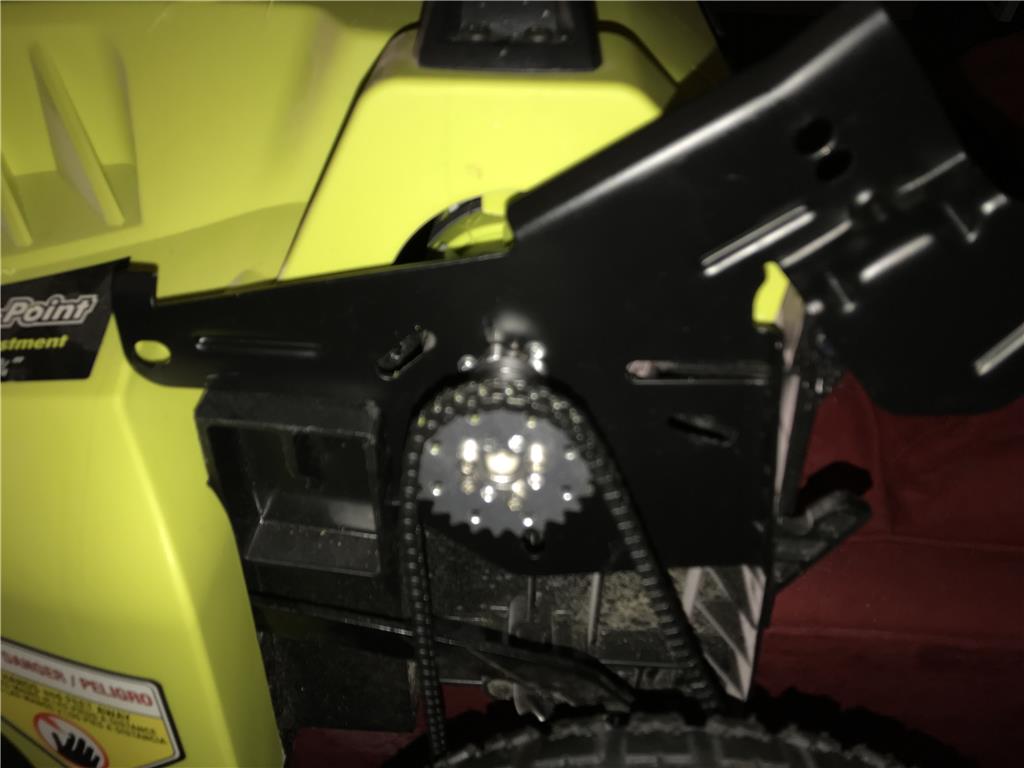
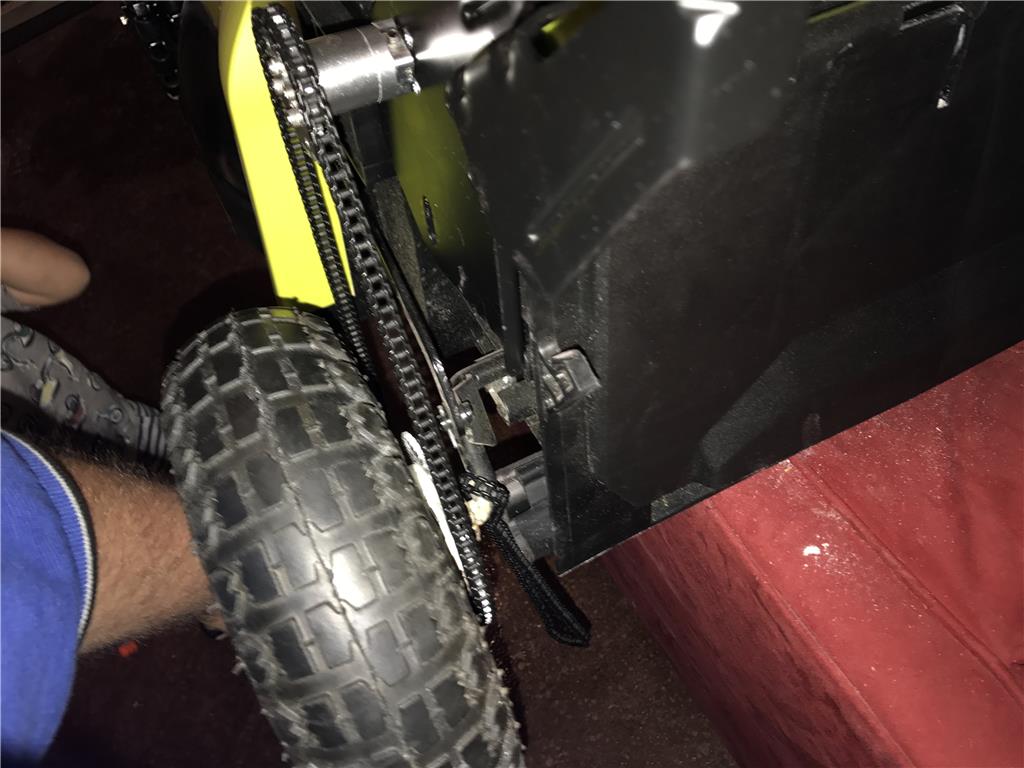

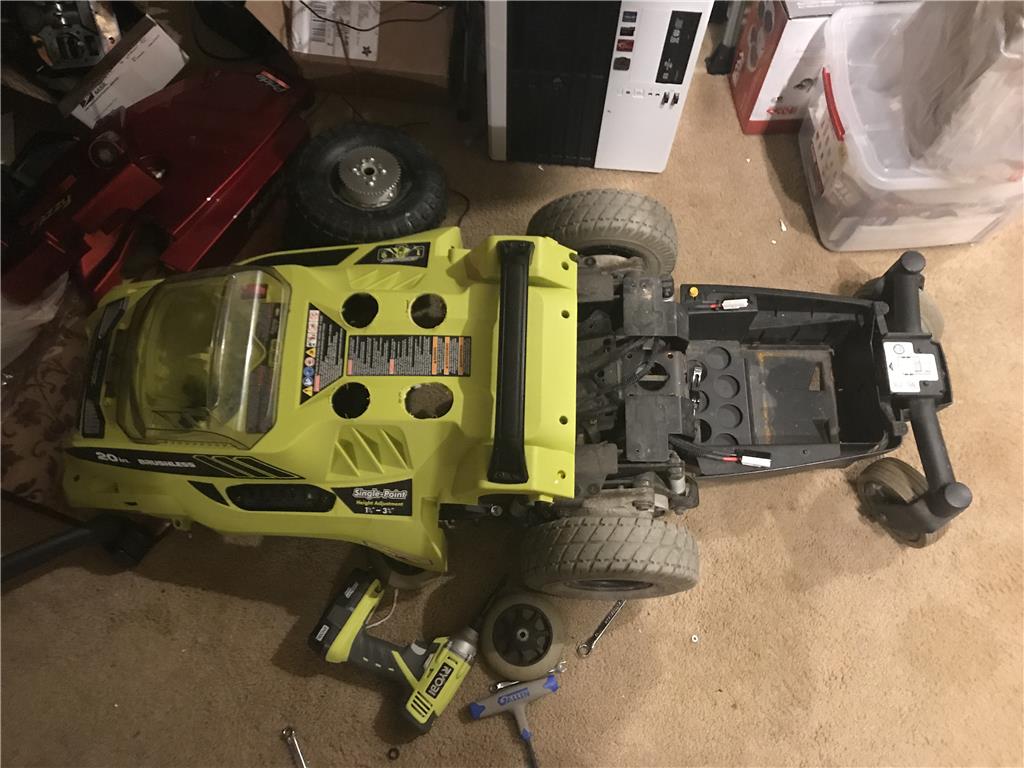
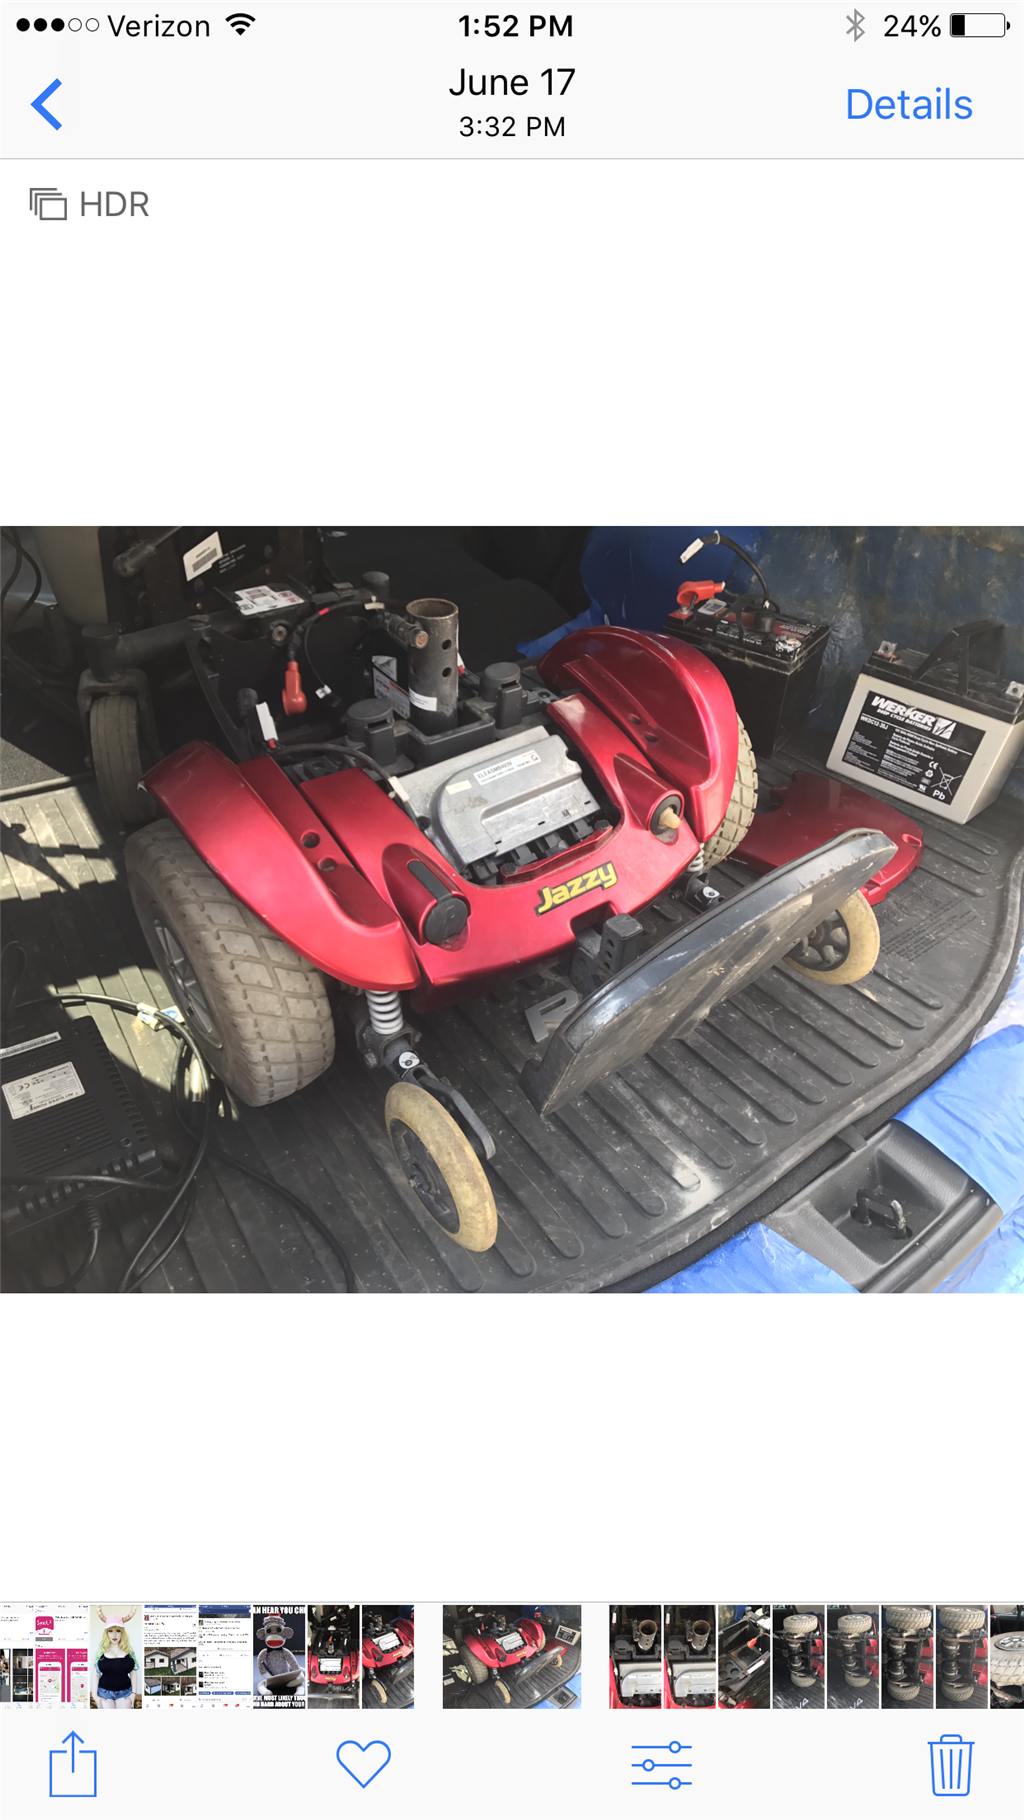
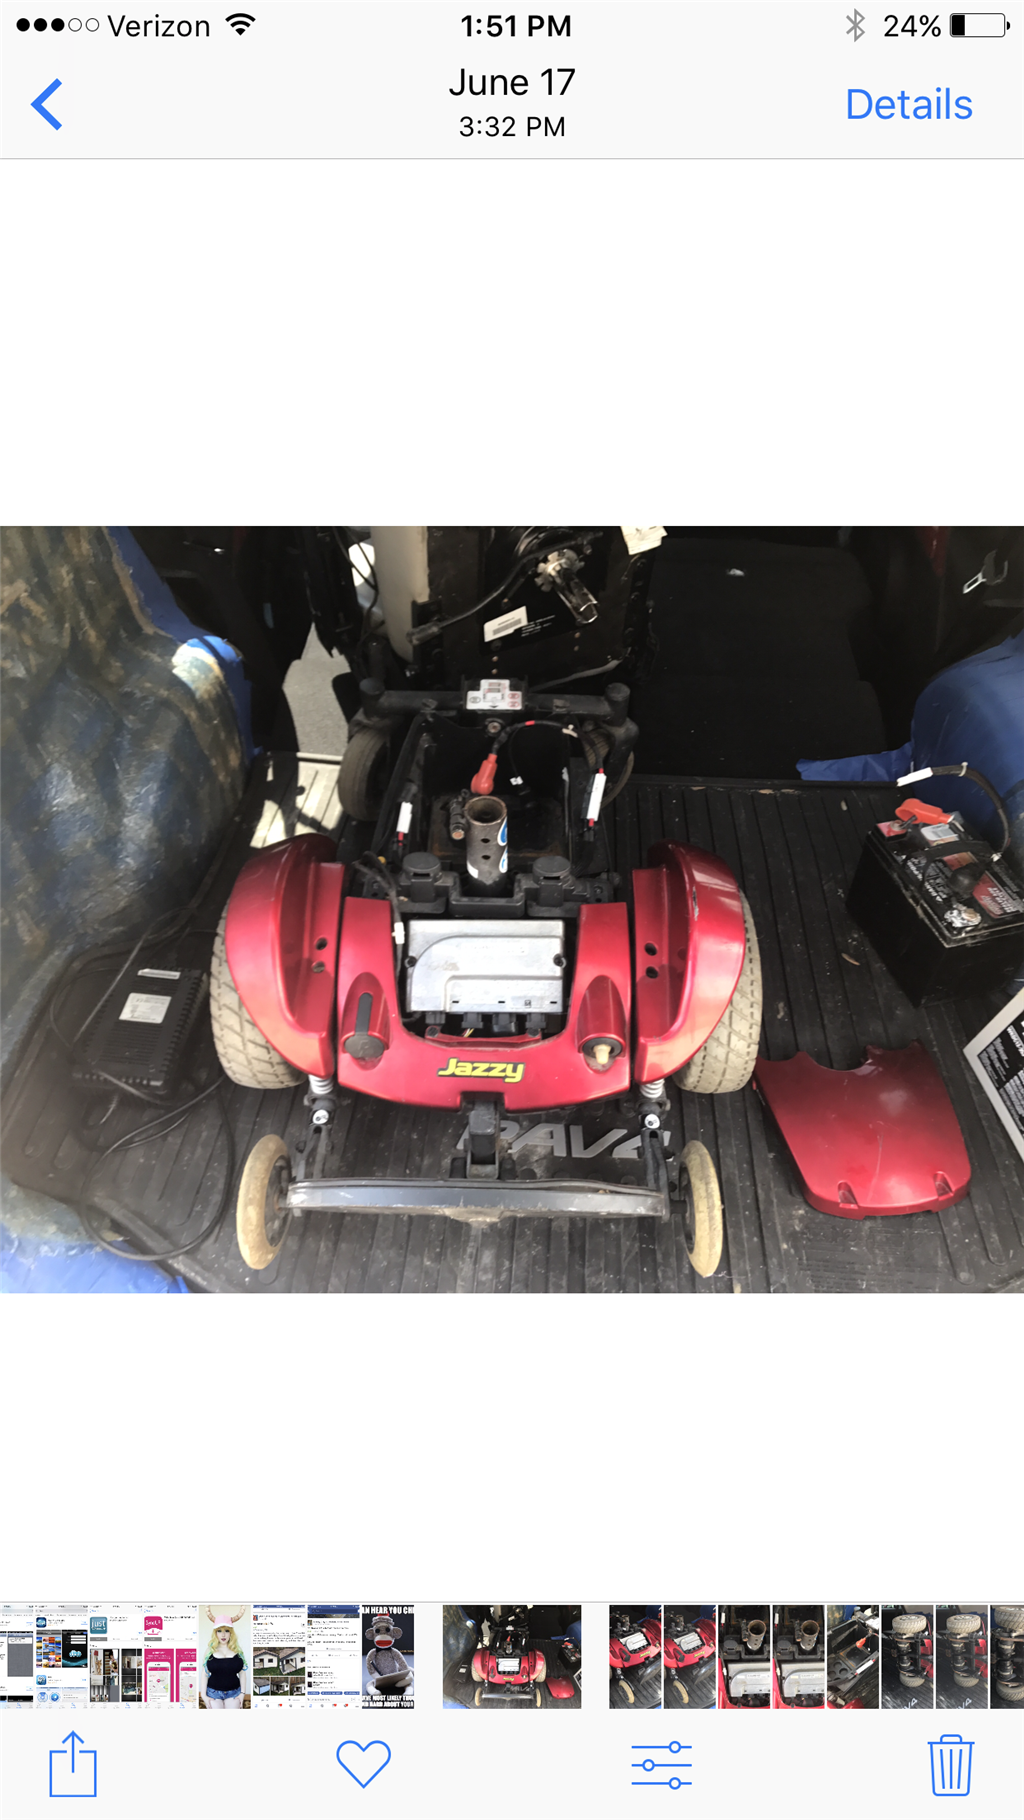
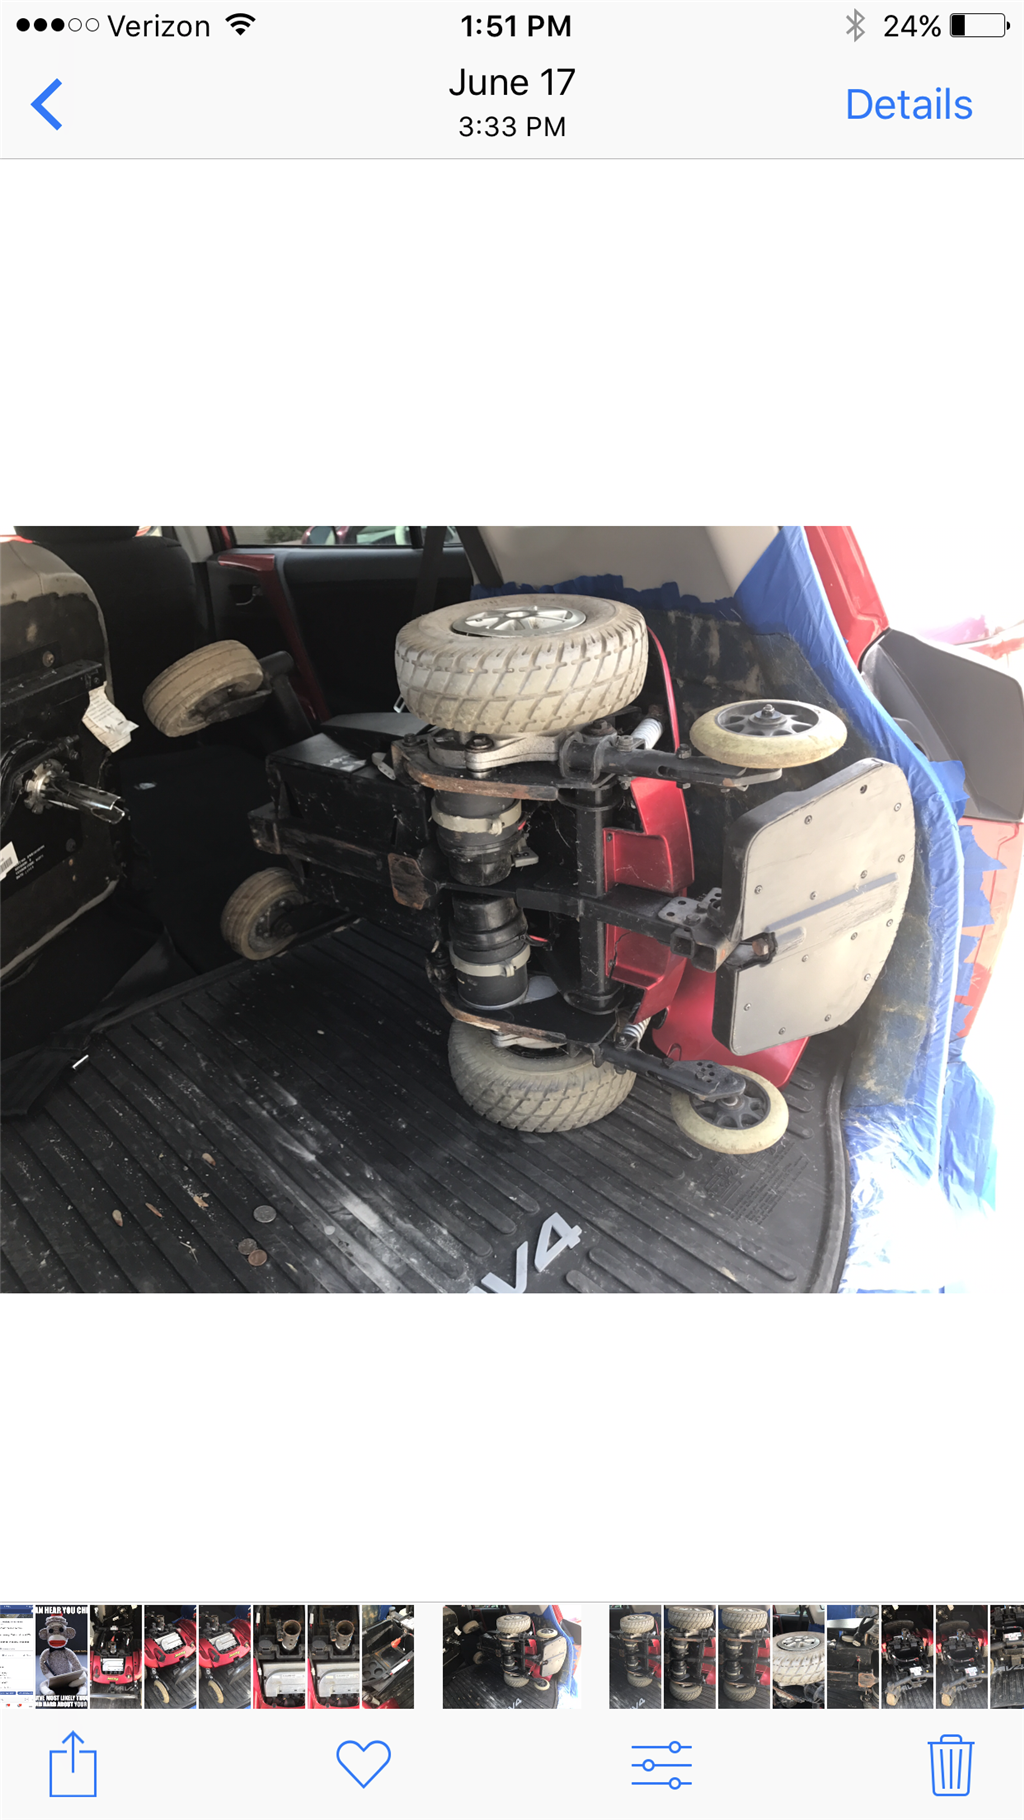
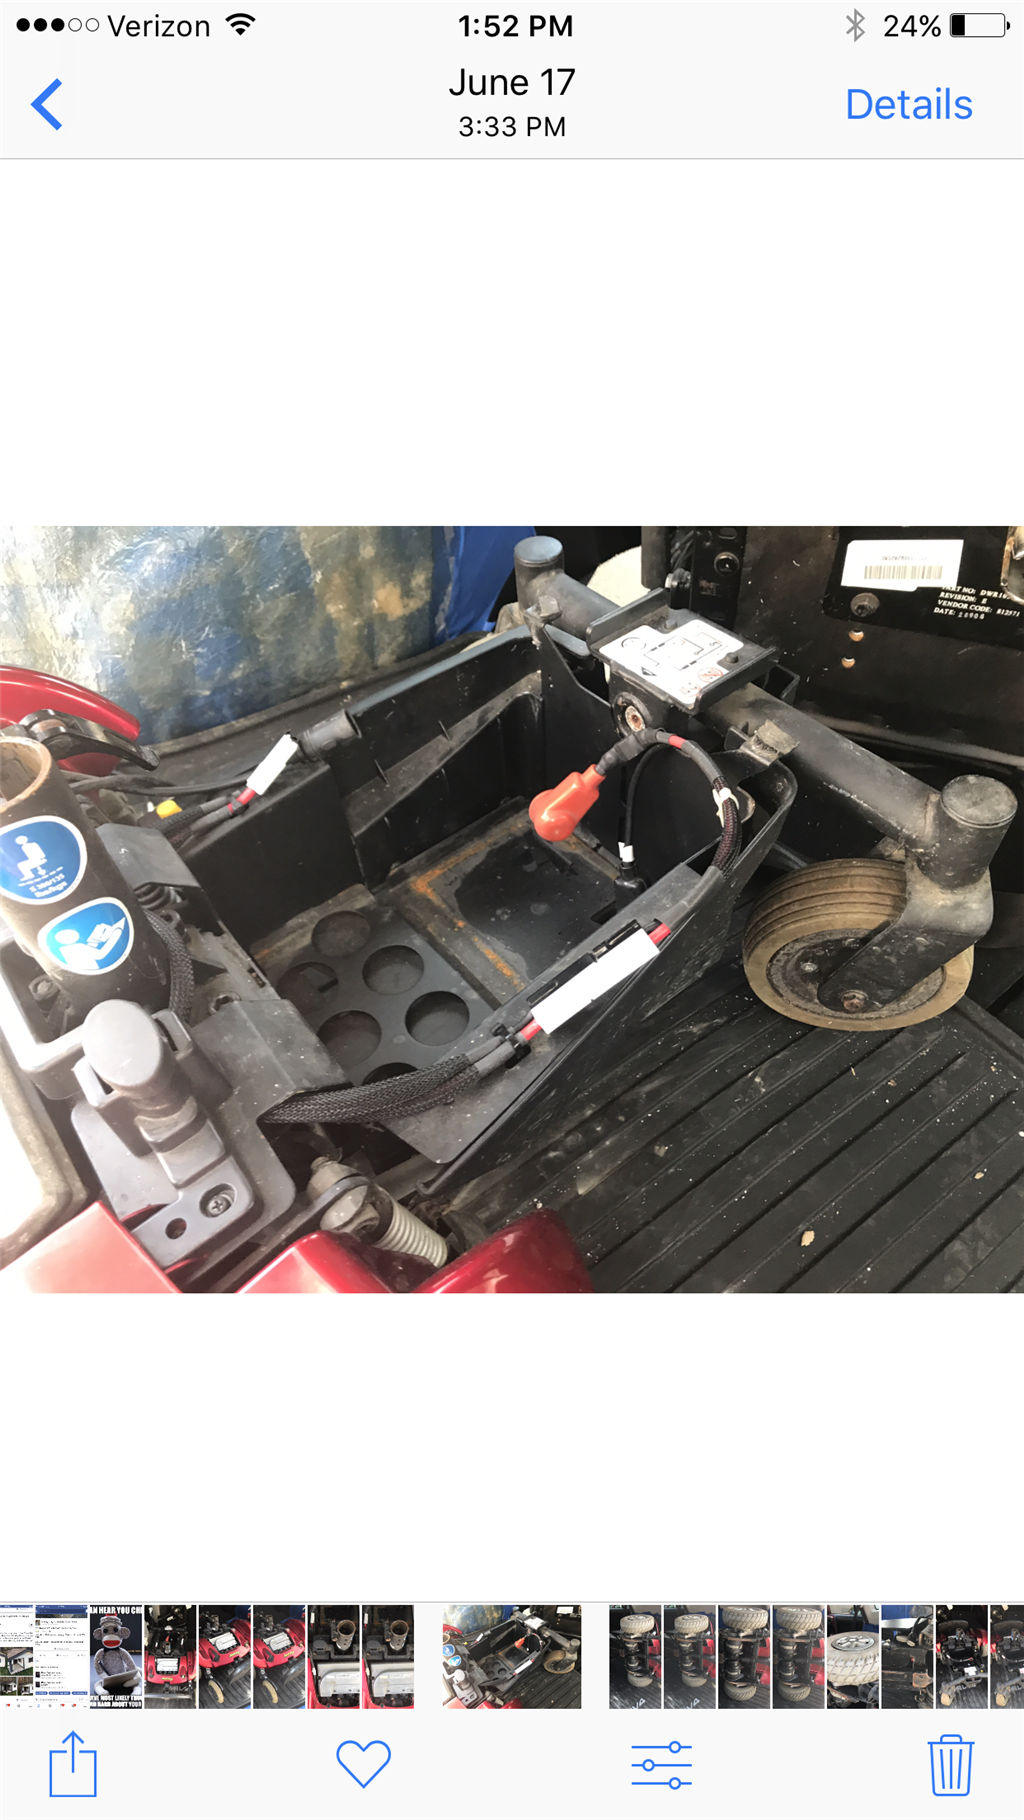
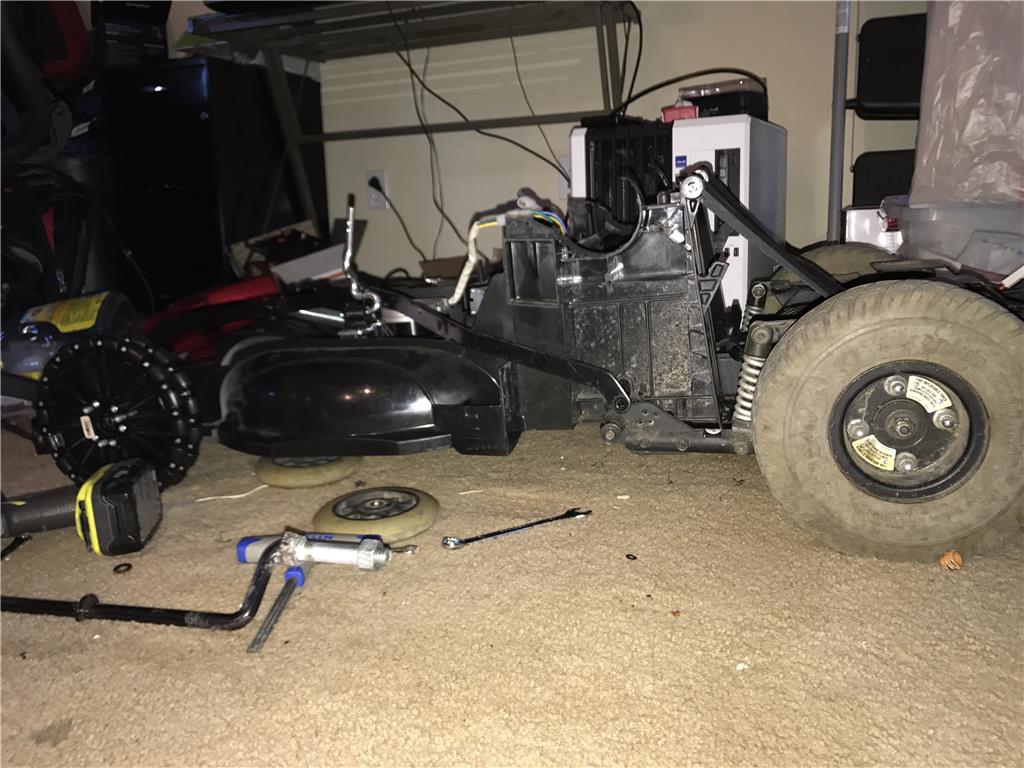
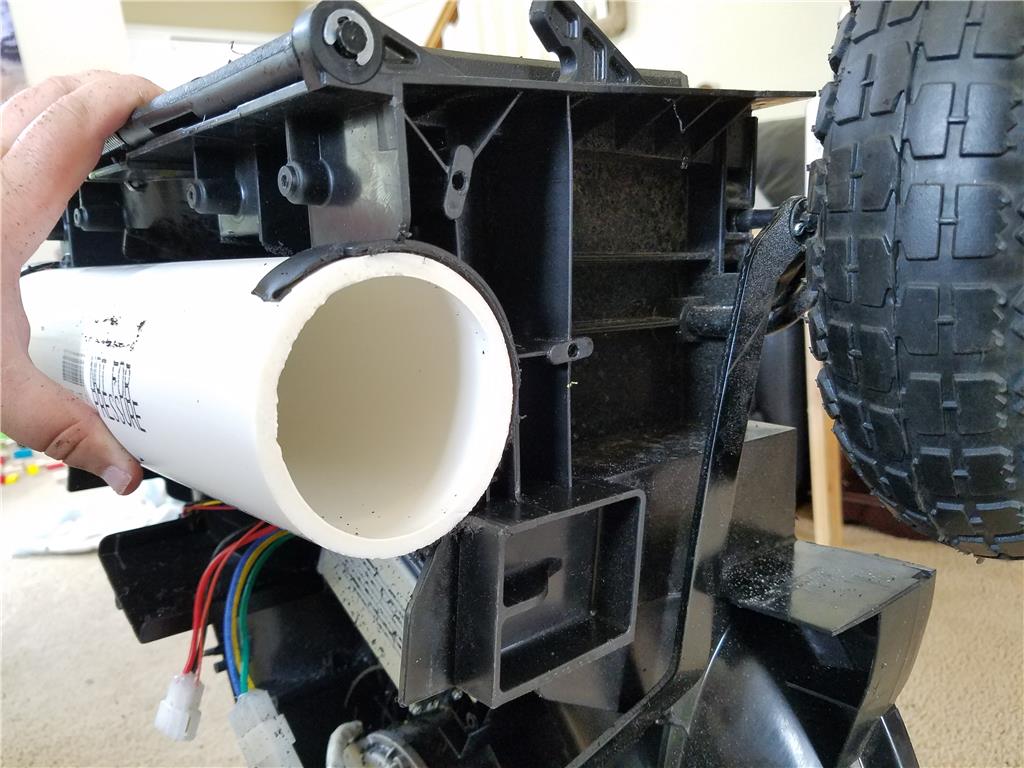
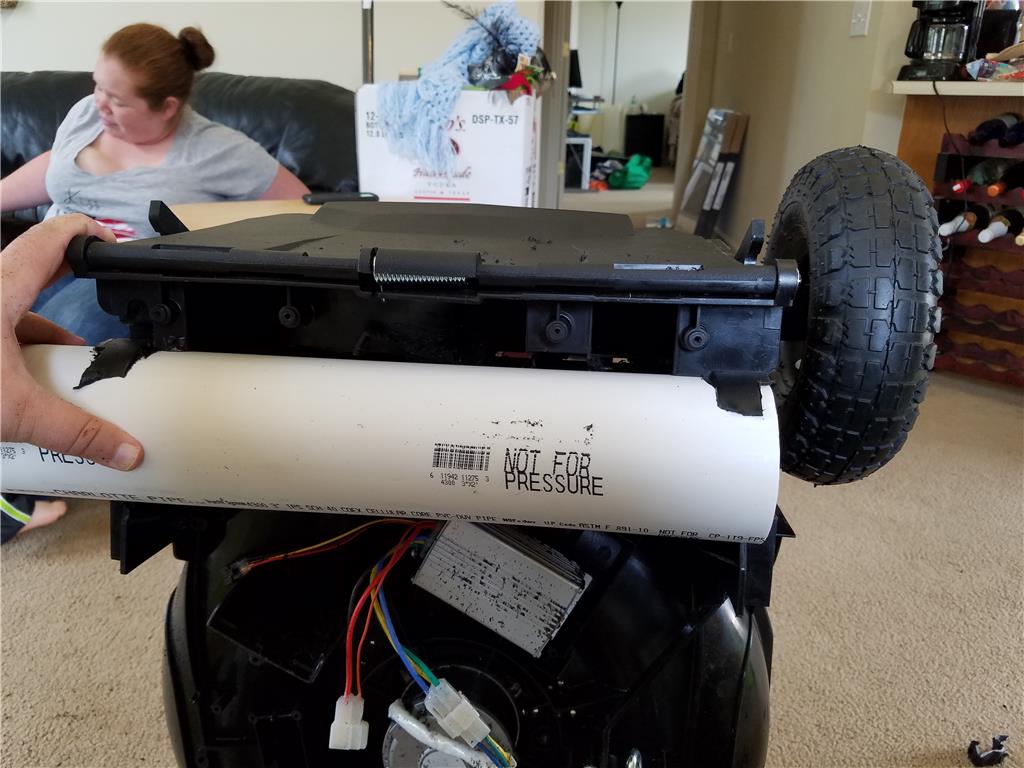
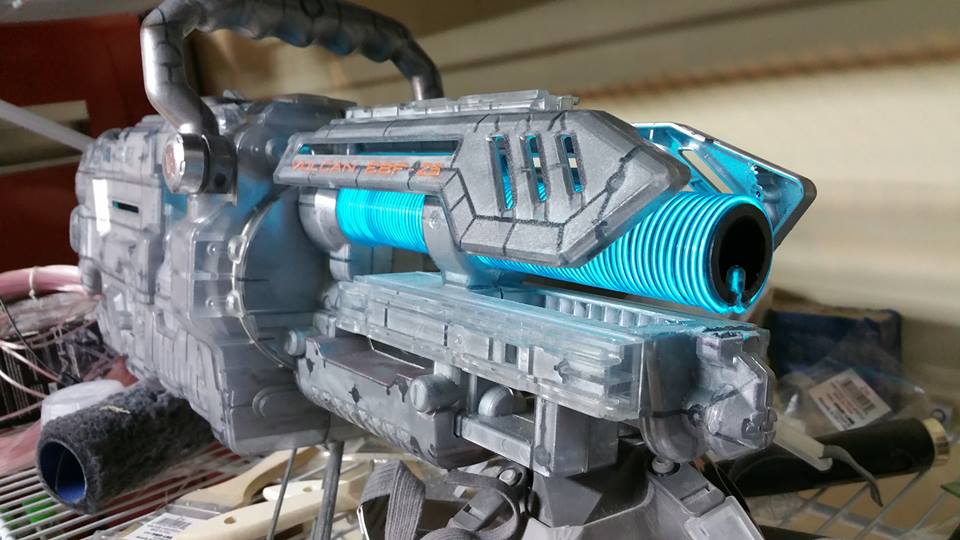


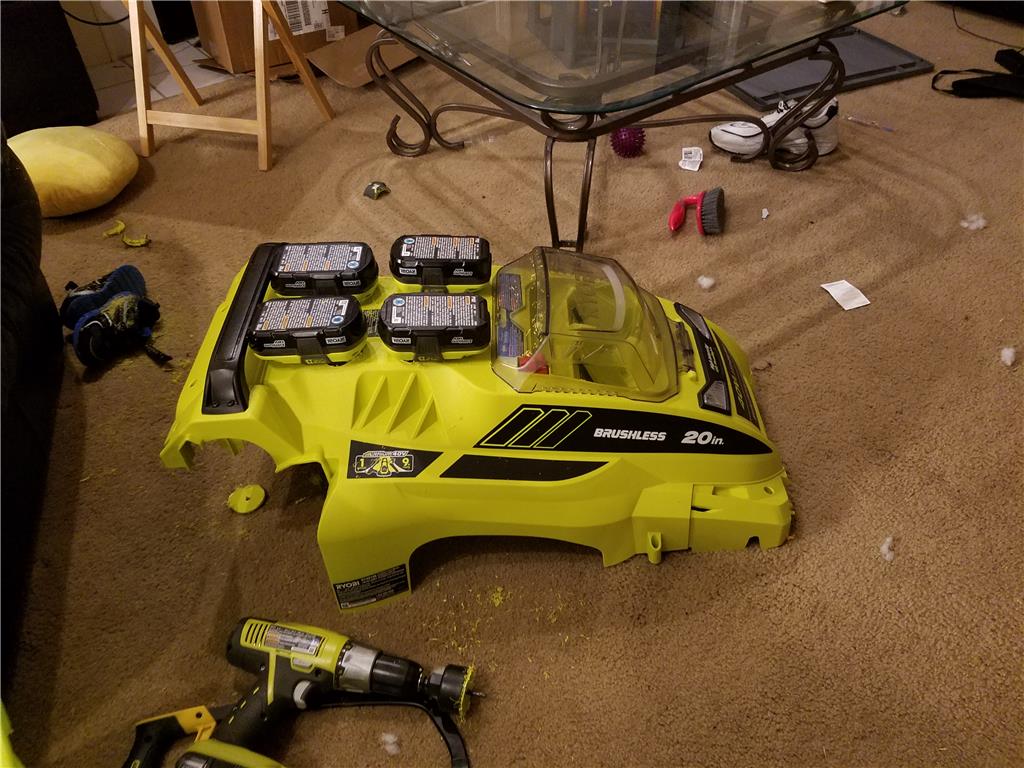

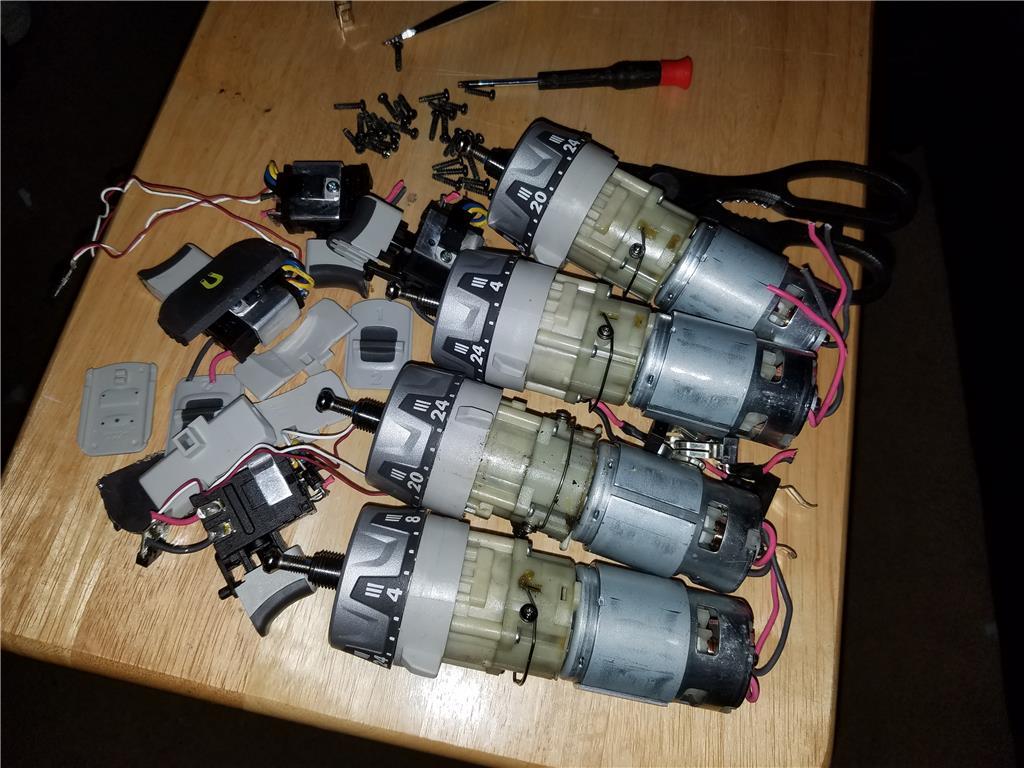

Hello all, I am getting back in the saddle making robots now that I am moved into my new home and settled into my new job as a technician maintaining the Fiber Optics network in Chattanooga TN.
IM BACK !
By jstarne1
— Last update
Discover more robots
PJ's Ez-Truck
Convert an R/C truck to EZ-Robot using EZ-B v4, IoTiny, L298N H-bridge, HC-SR04 sensors, servos, camera and scripted...
Luis's Using The Sure Dc Ss503v100 With Ezb4 From Ez-Robots
Connect Sure DC SS503V100 compass to EZ-Robots EZB4 via UART: RX/TX wiring, set OPT high to 3.3V, 4ft wire tested,...
Hstud's Hunters1st Robot Sam
DIY robot S.A.M. built by 8-year-old Hunter using EZ-Robot v3 and simple parts, dollar-store body, PVC arms, LEDs and...

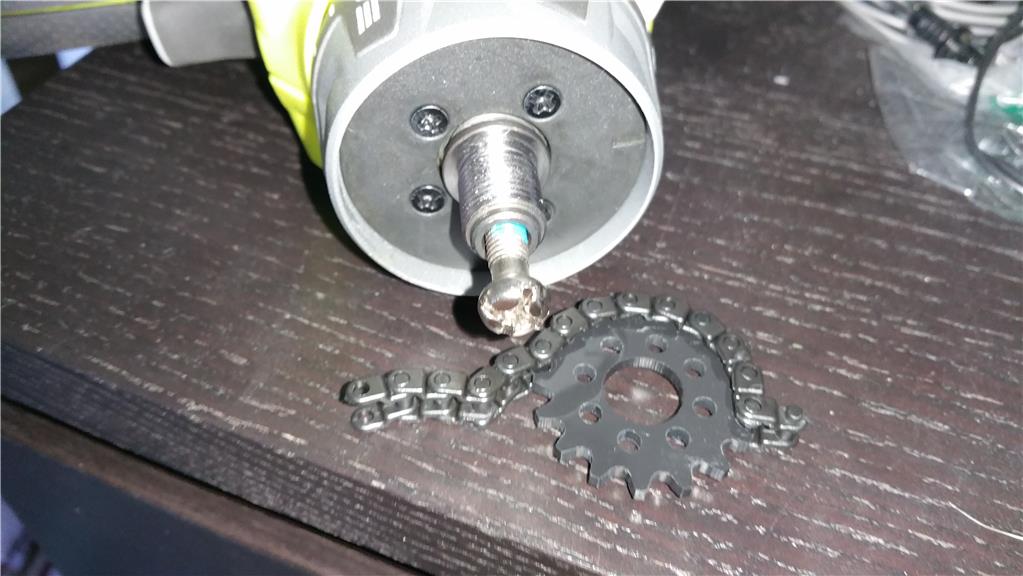
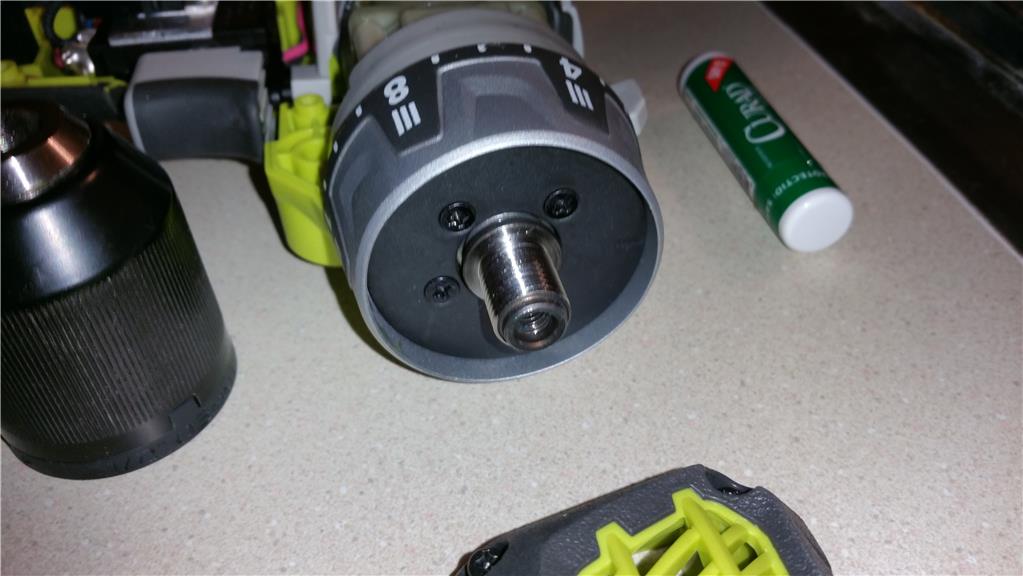
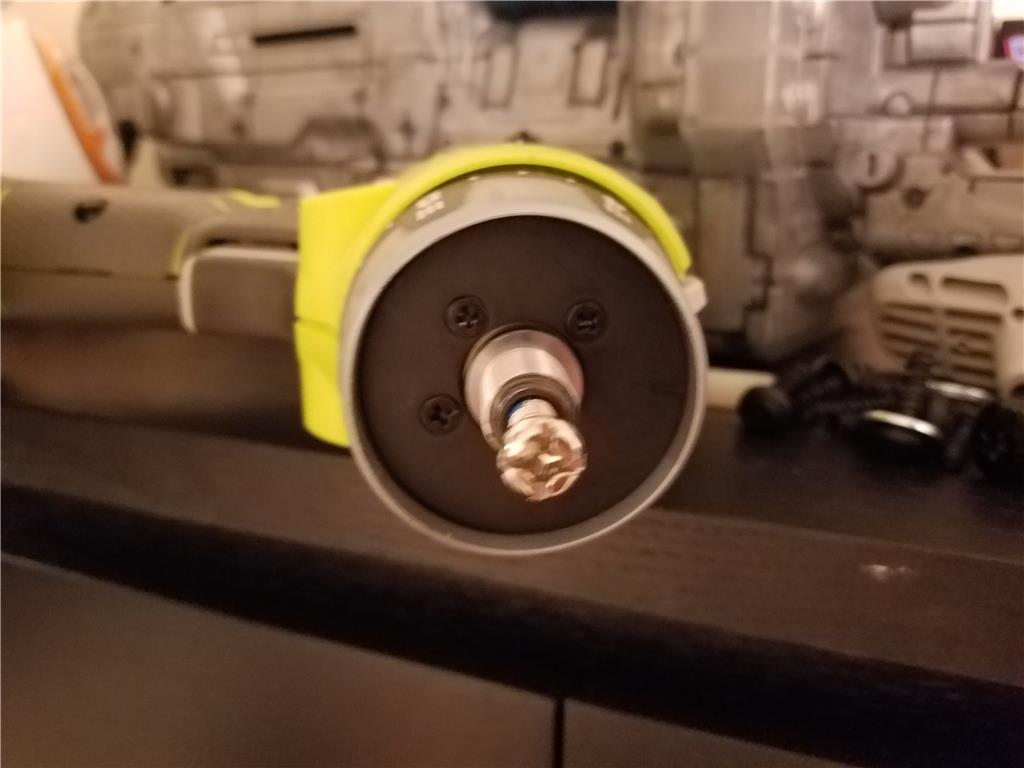
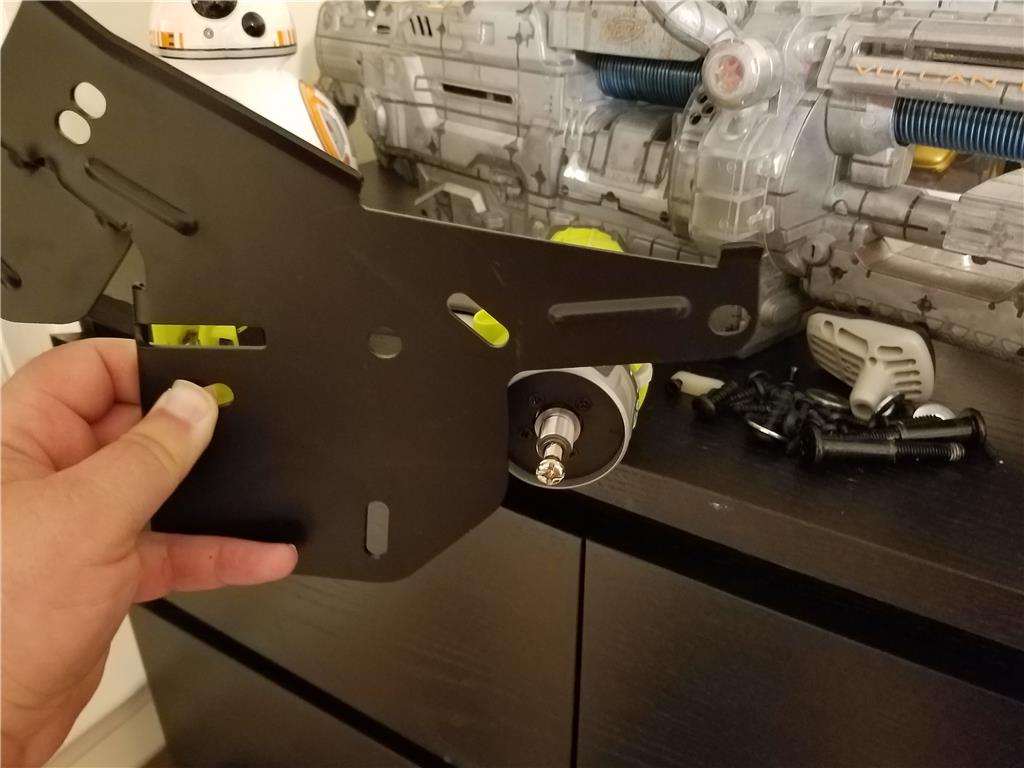
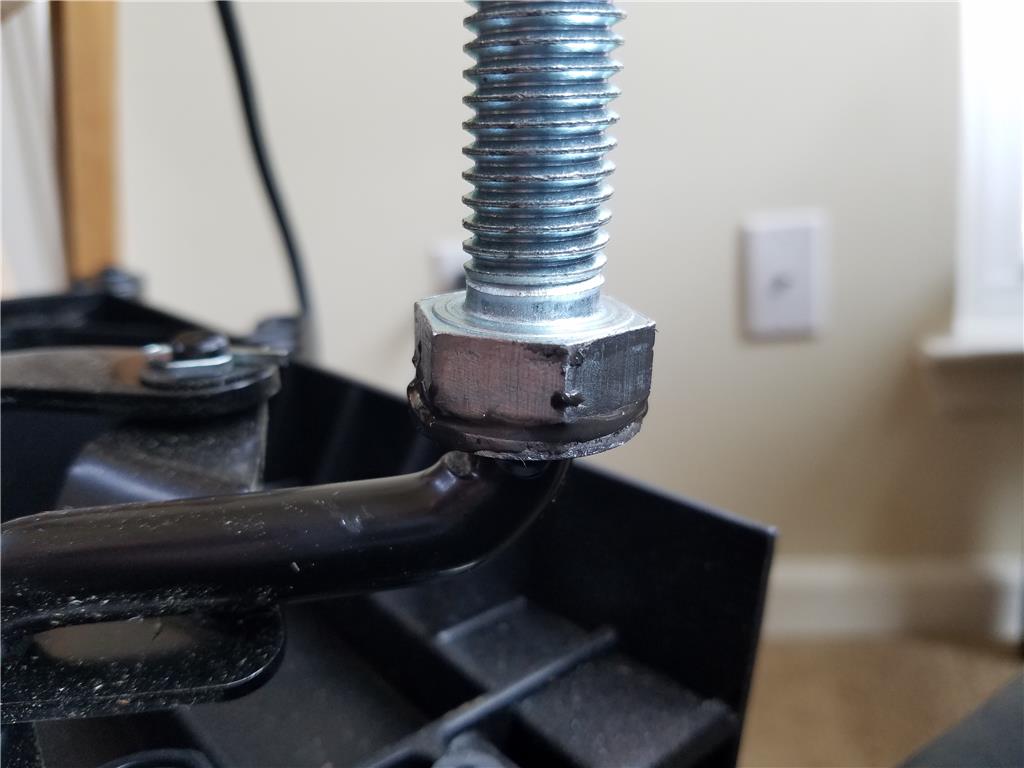
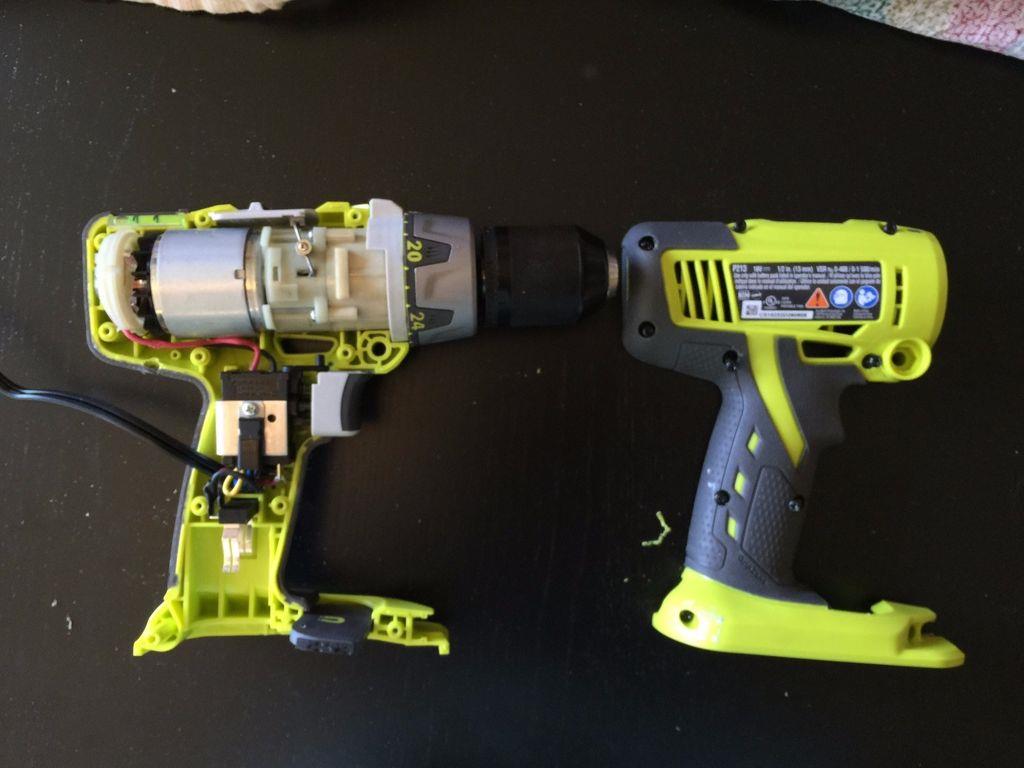
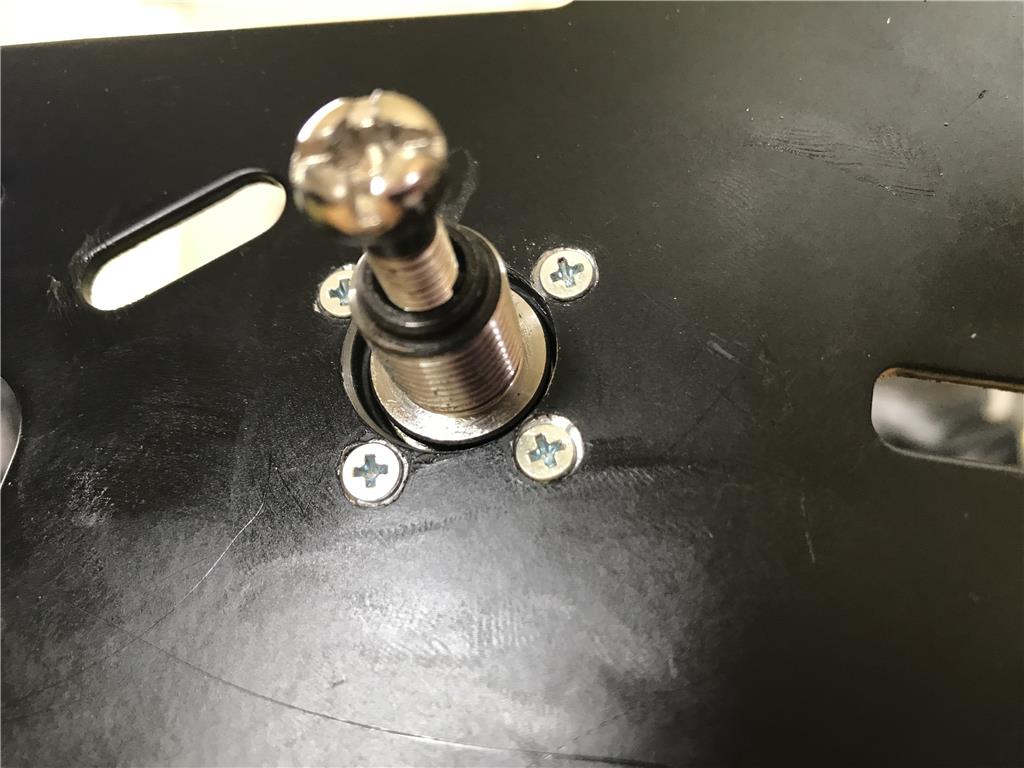
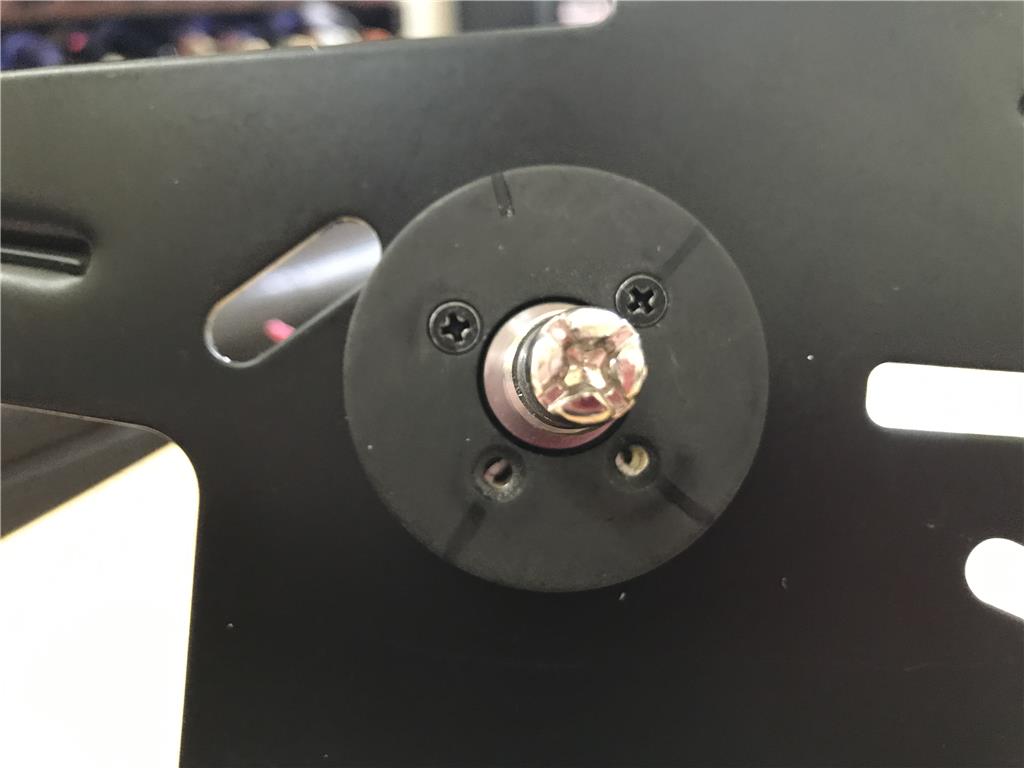
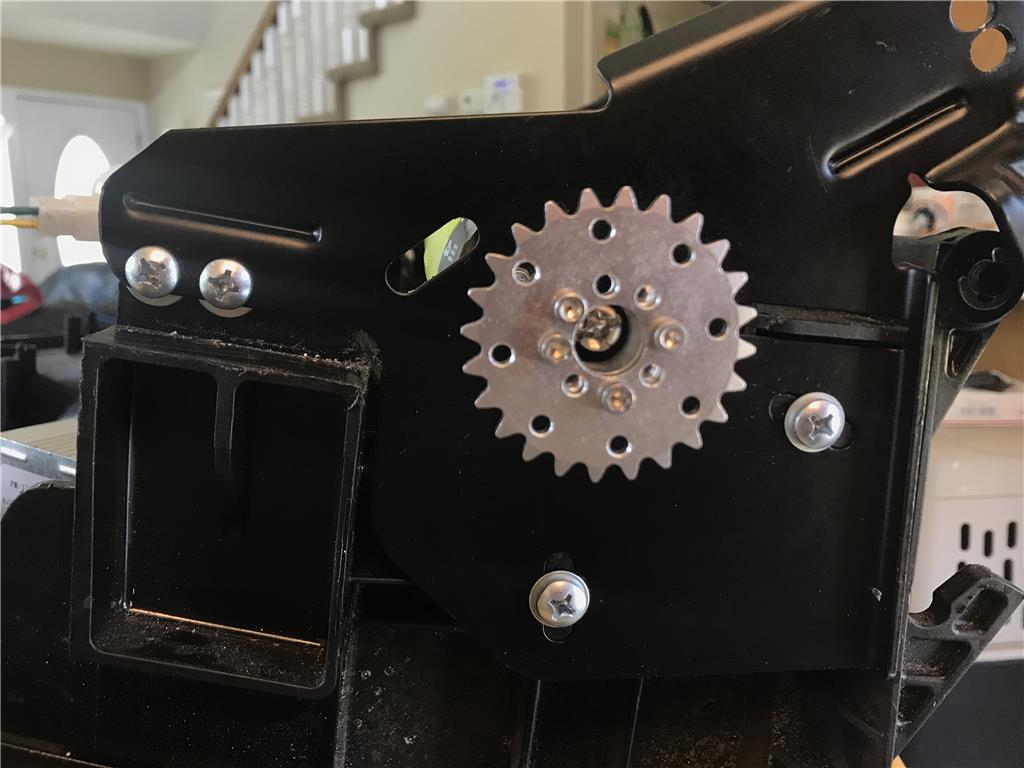
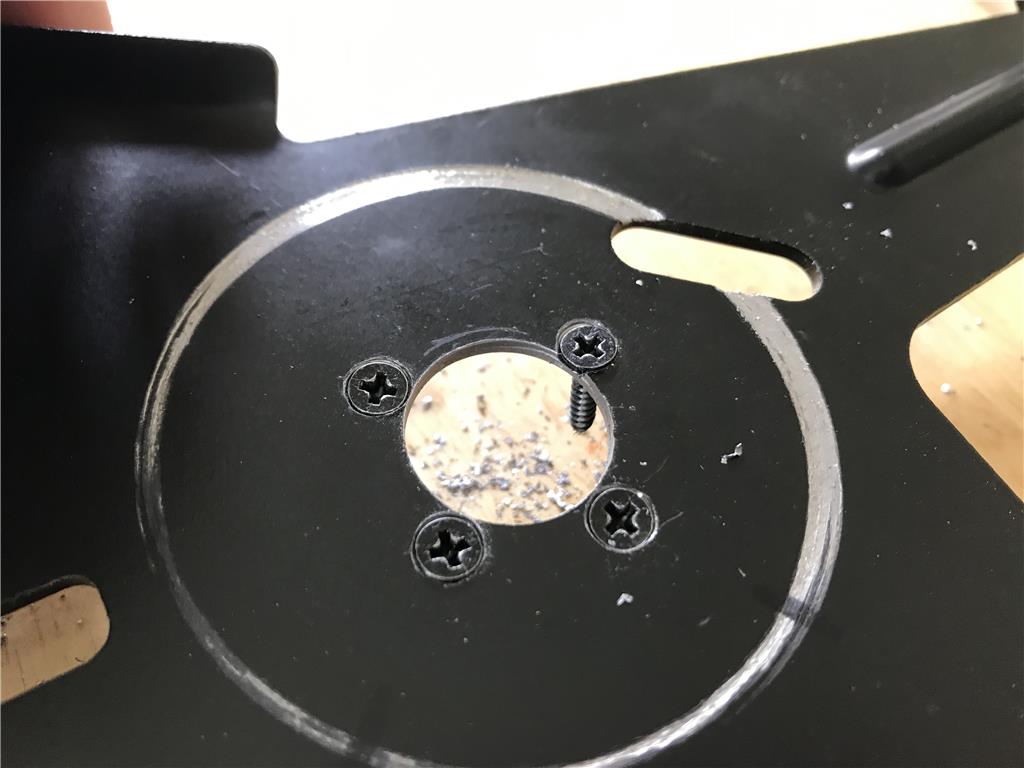
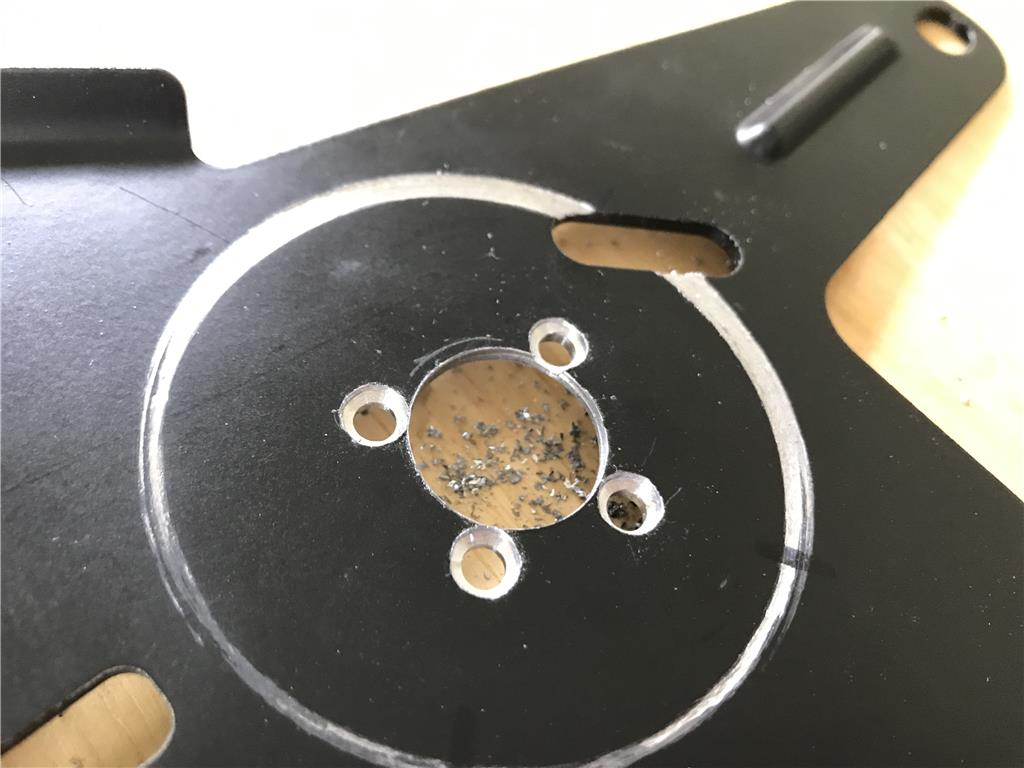
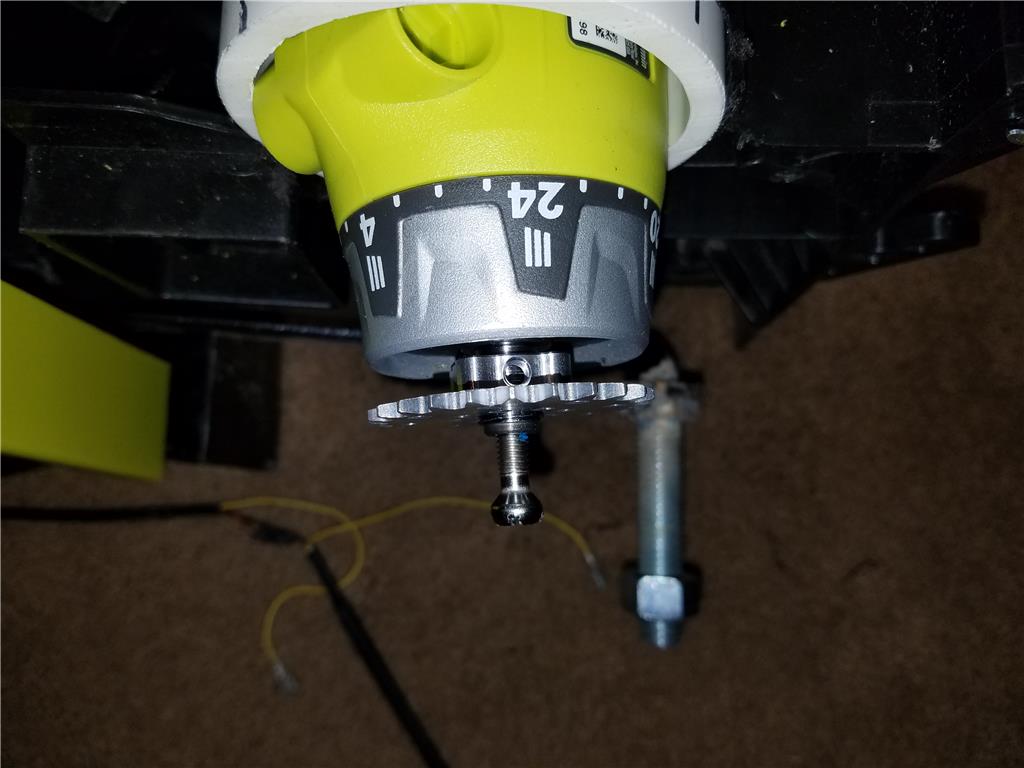
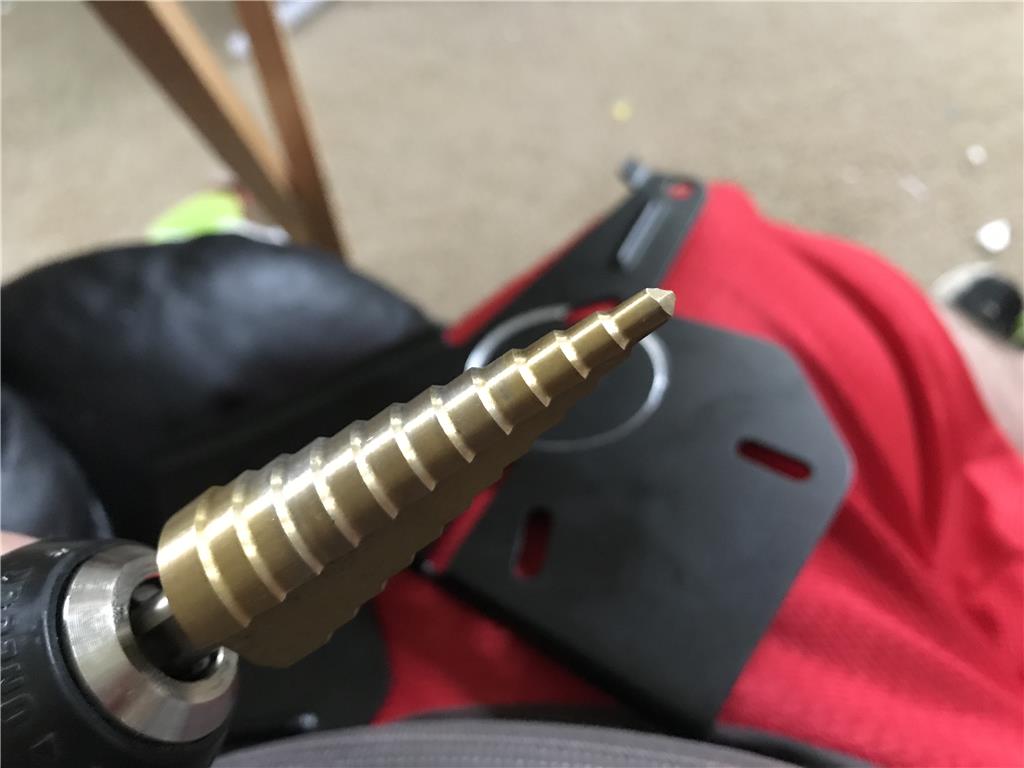
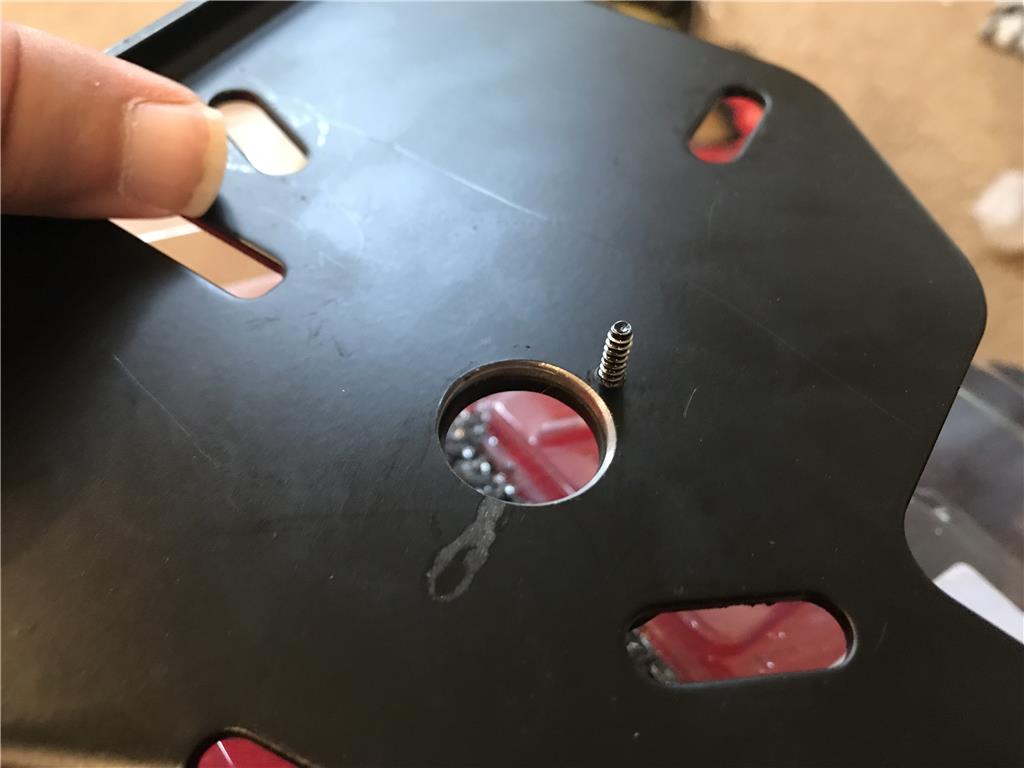
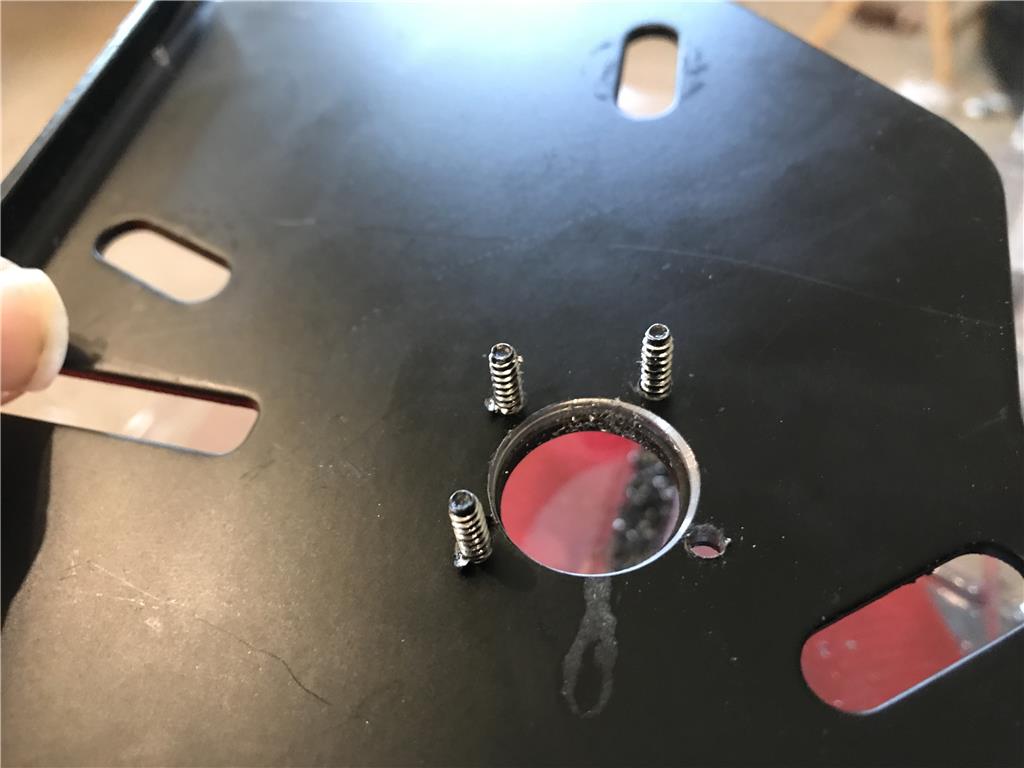
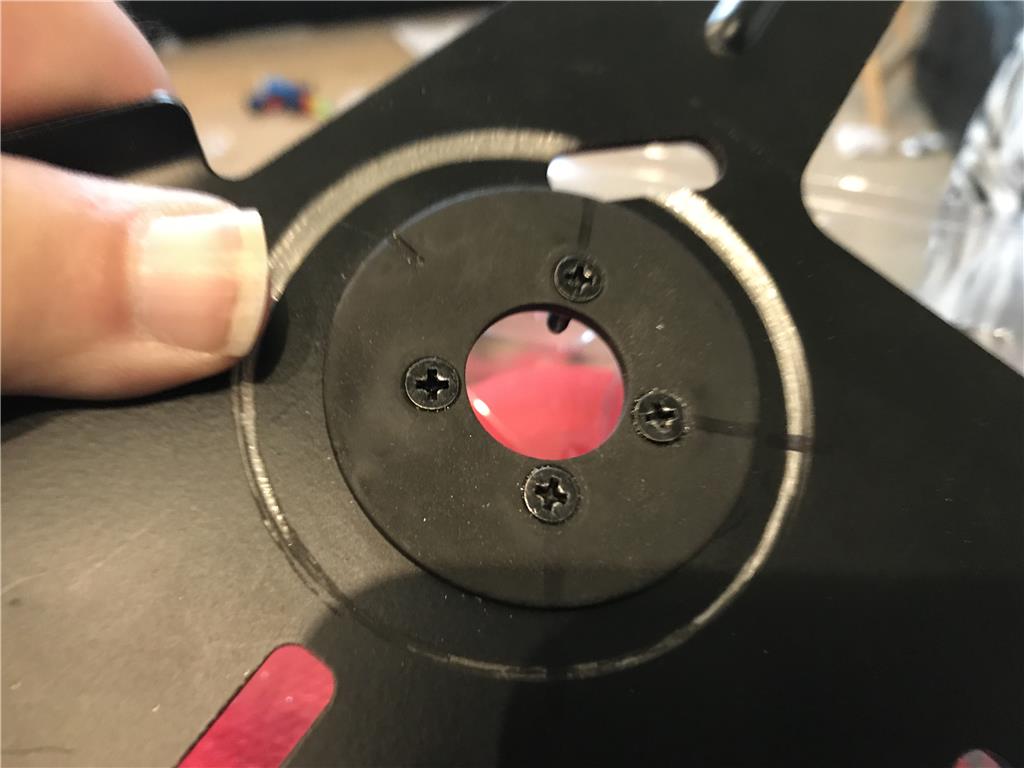
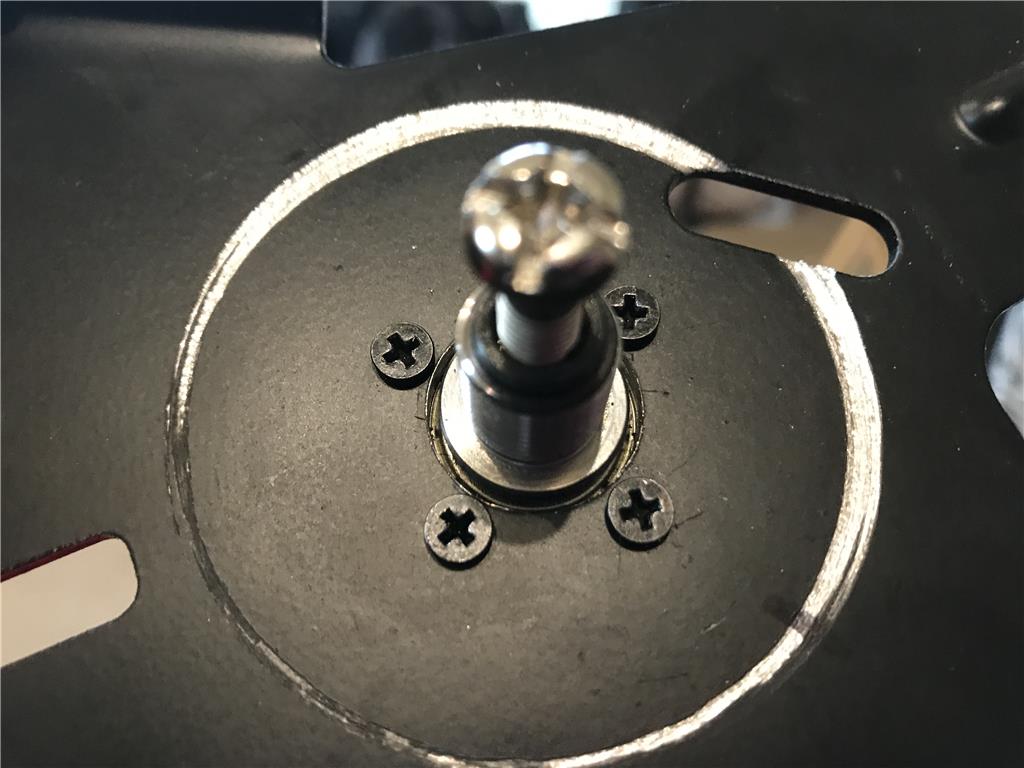
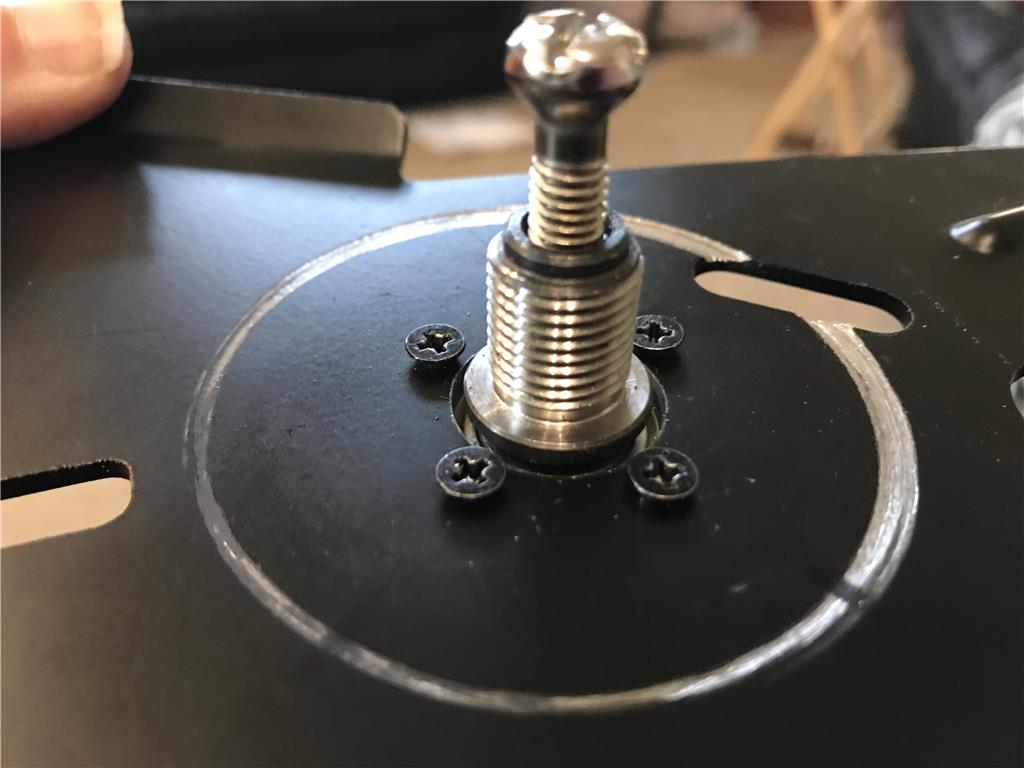
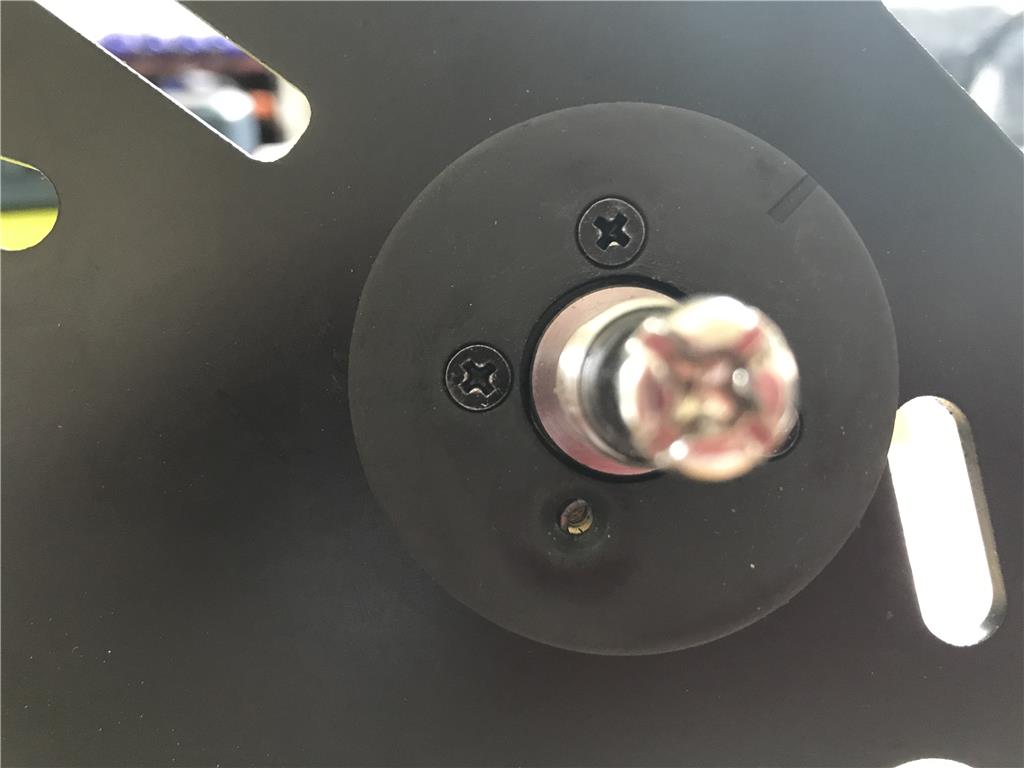
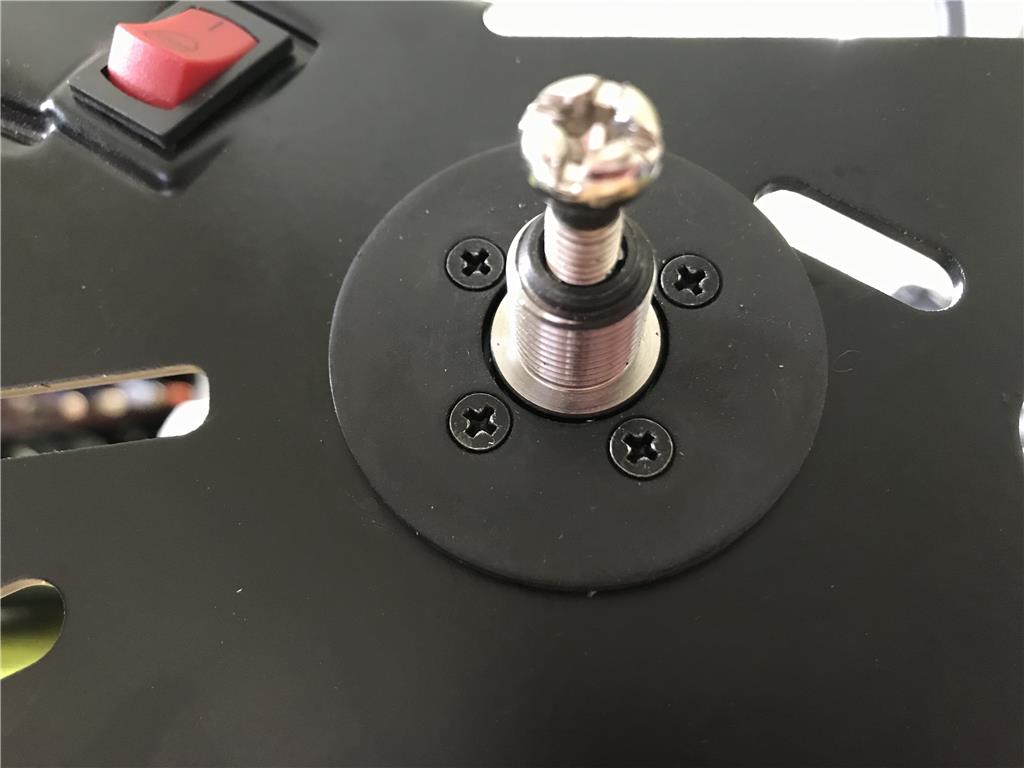
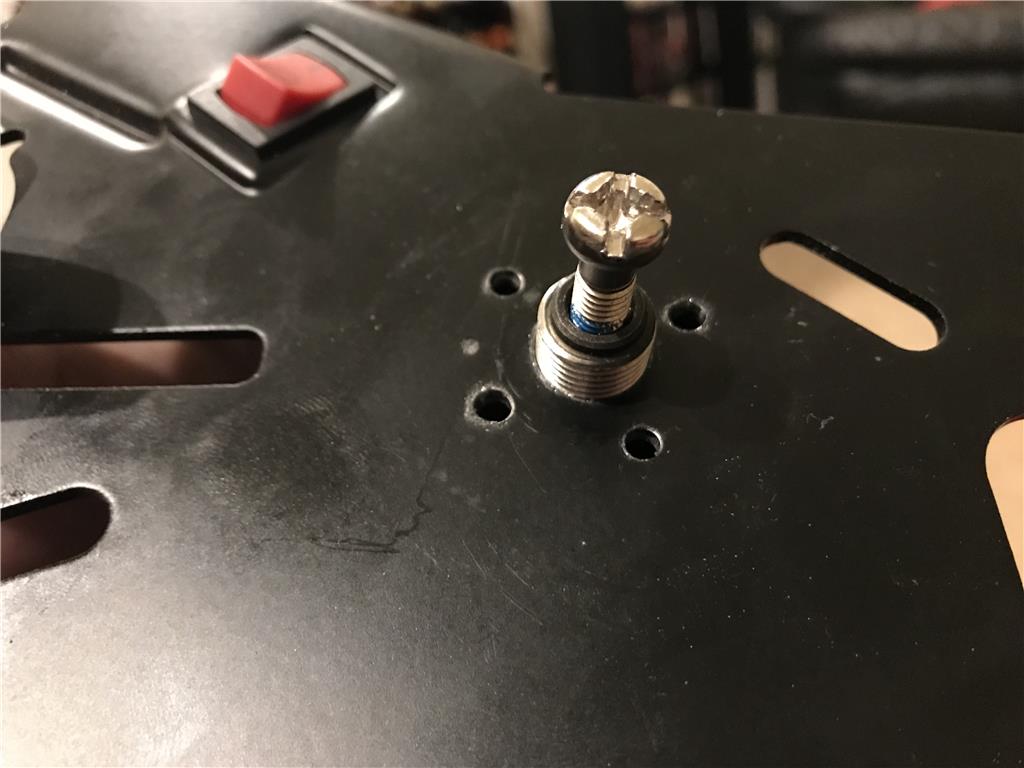
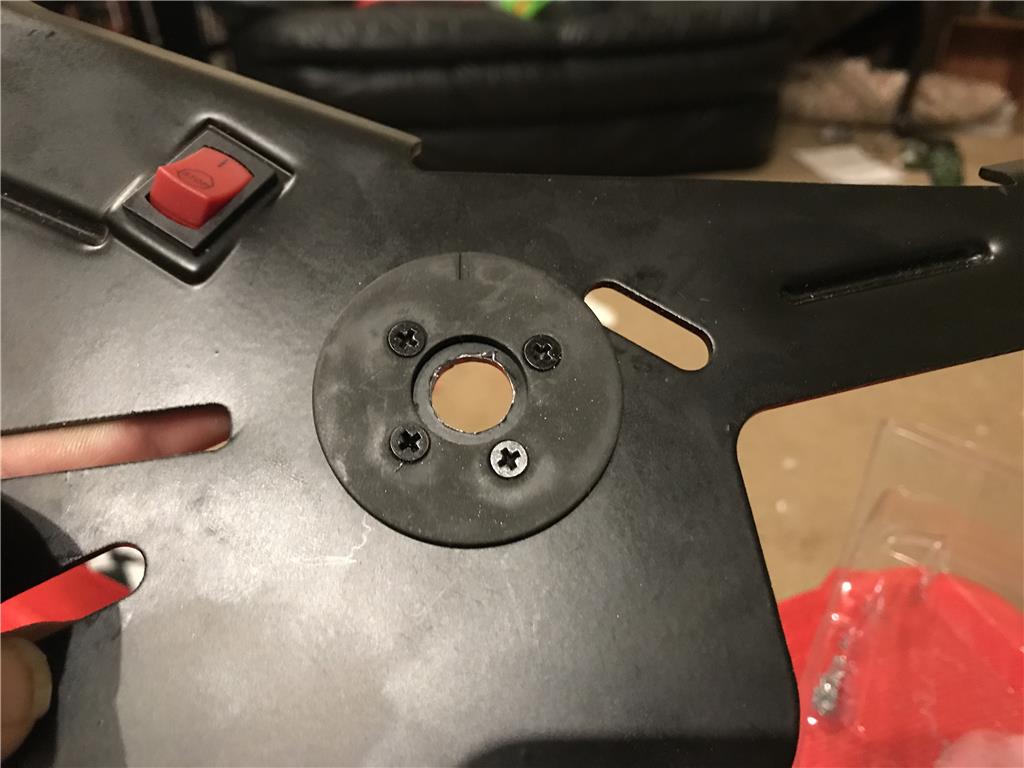
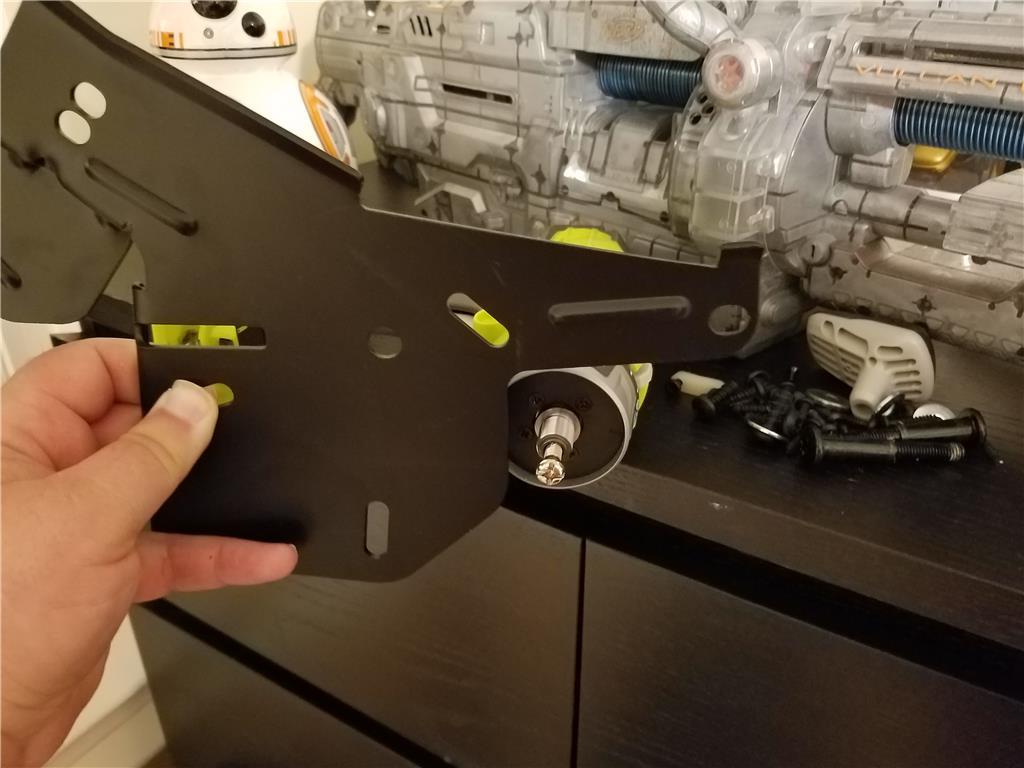
The screws are aligned with the gearbox holes but these screws require a counter sink to screw all the way in. I will use the tip of the stepper /uni-bit to make a counter sink.
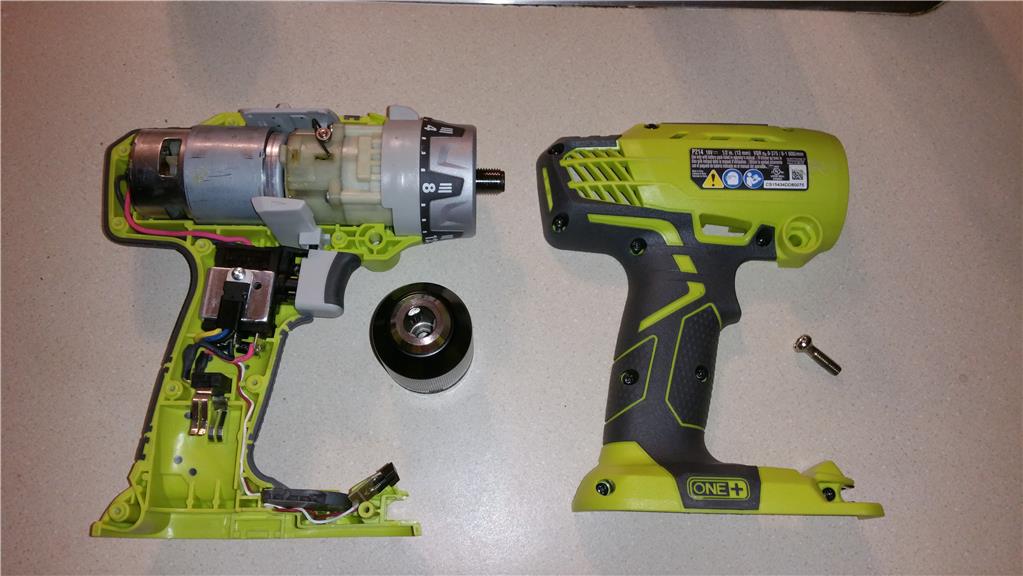
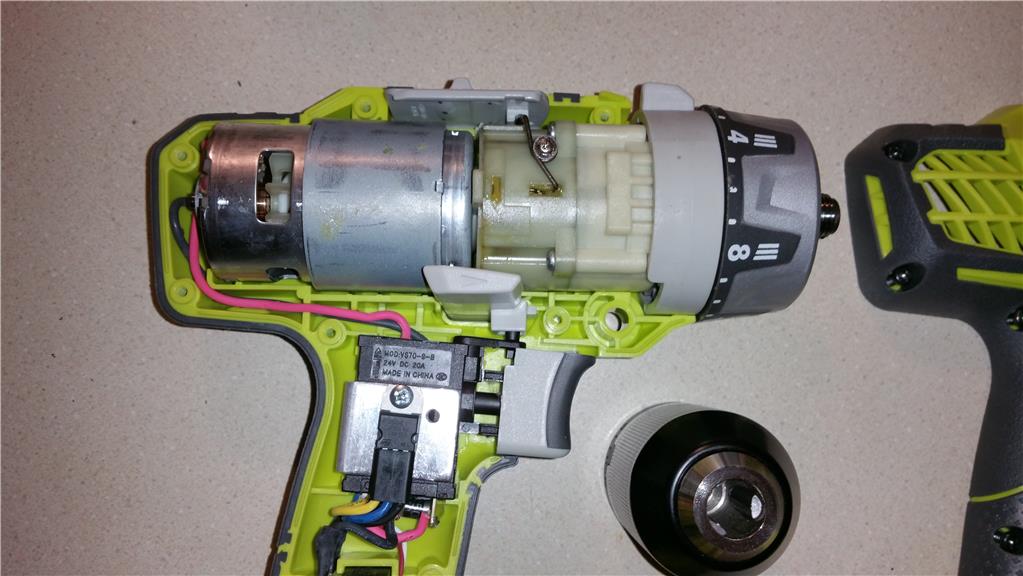
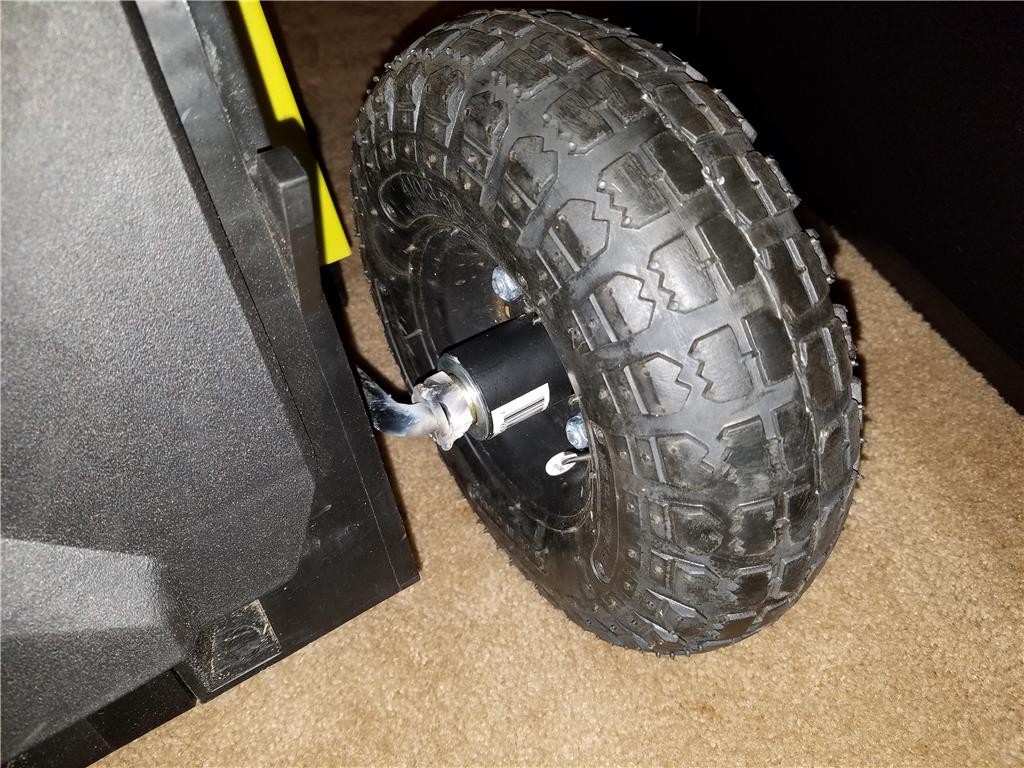
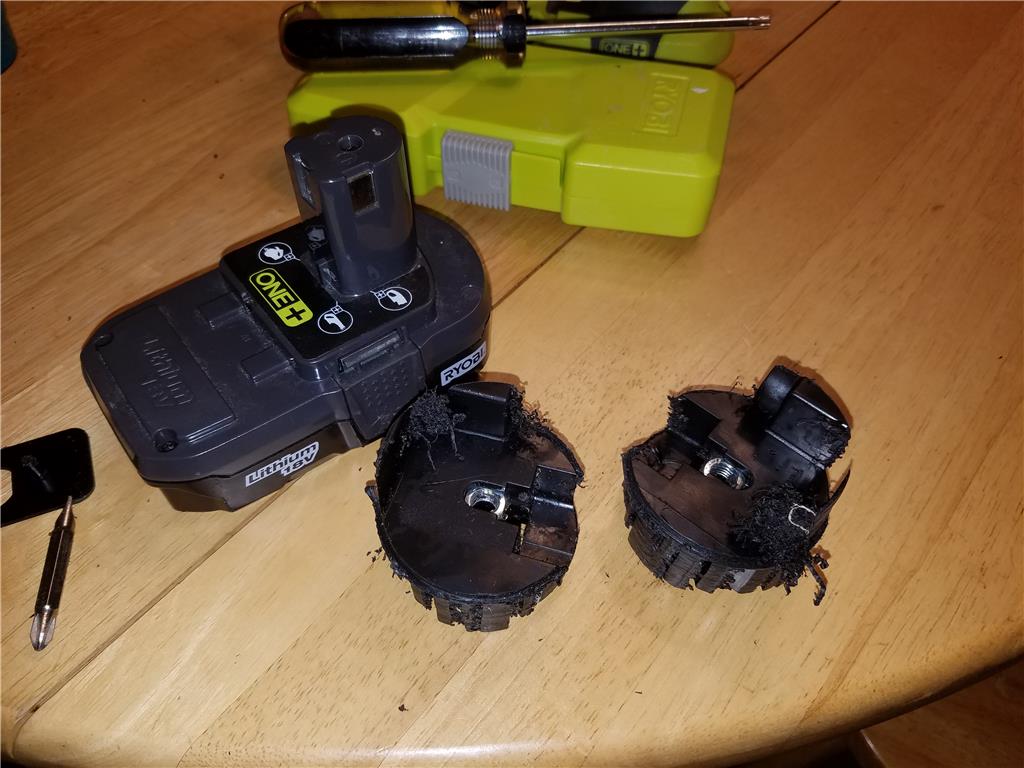
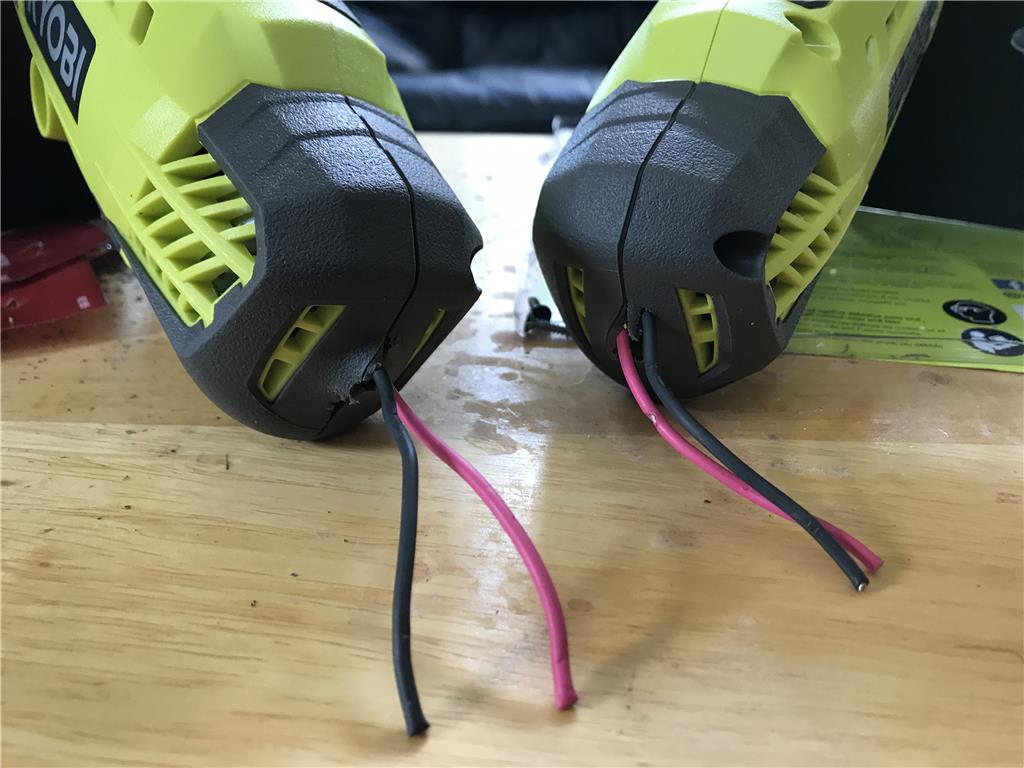
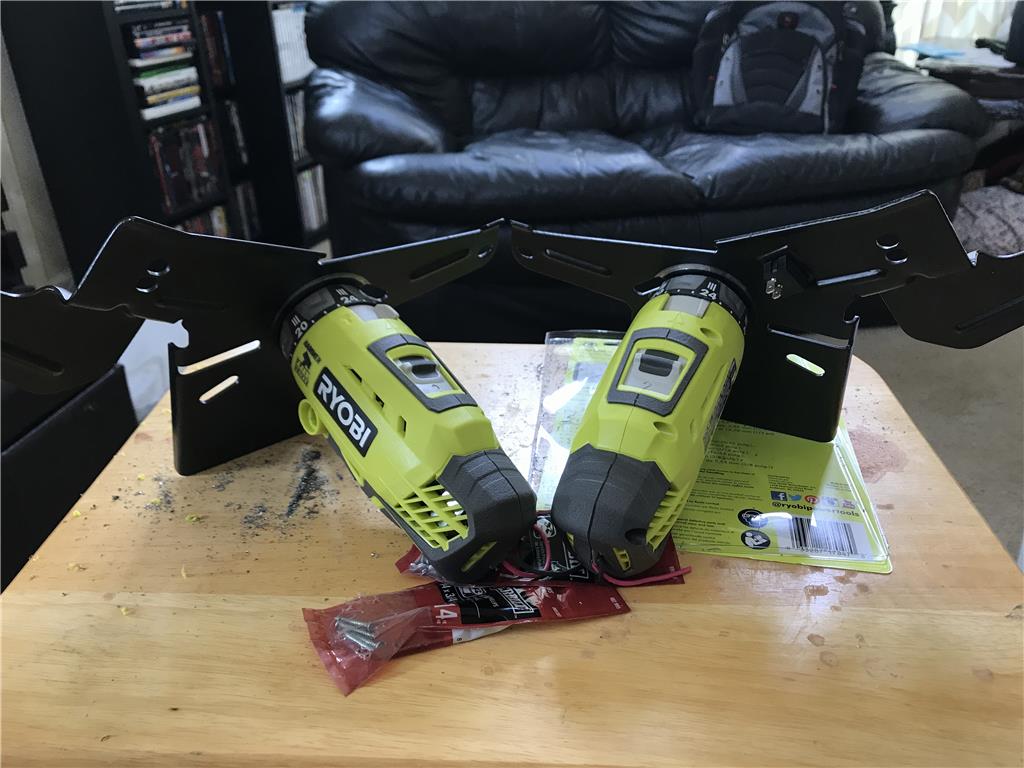
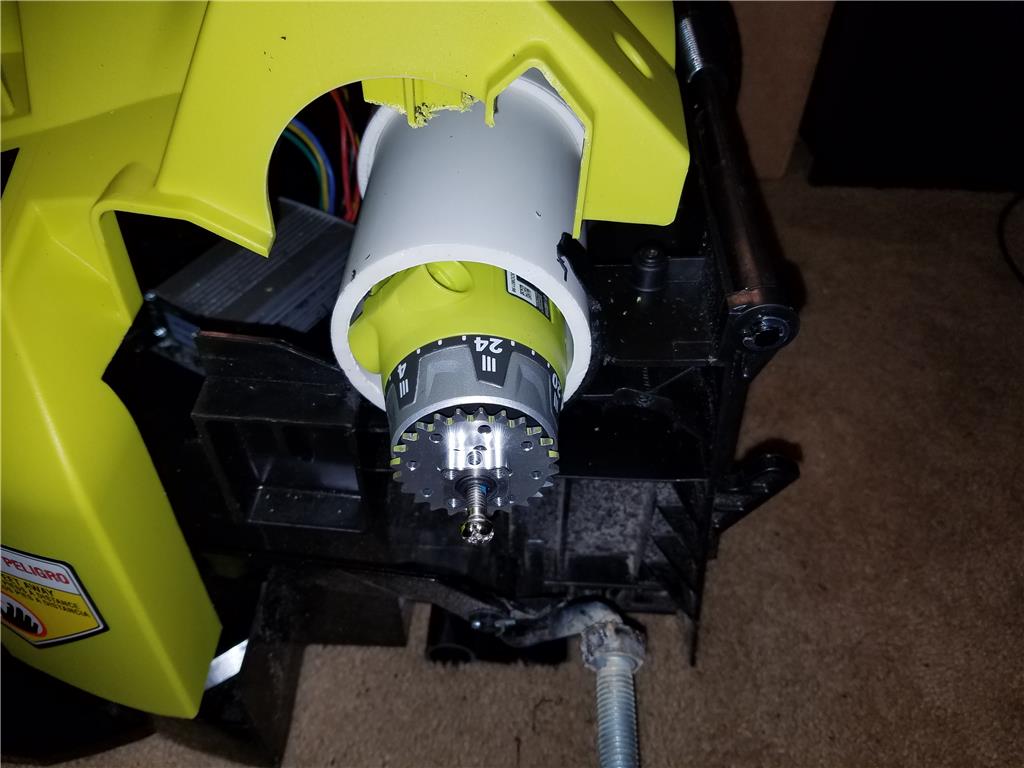
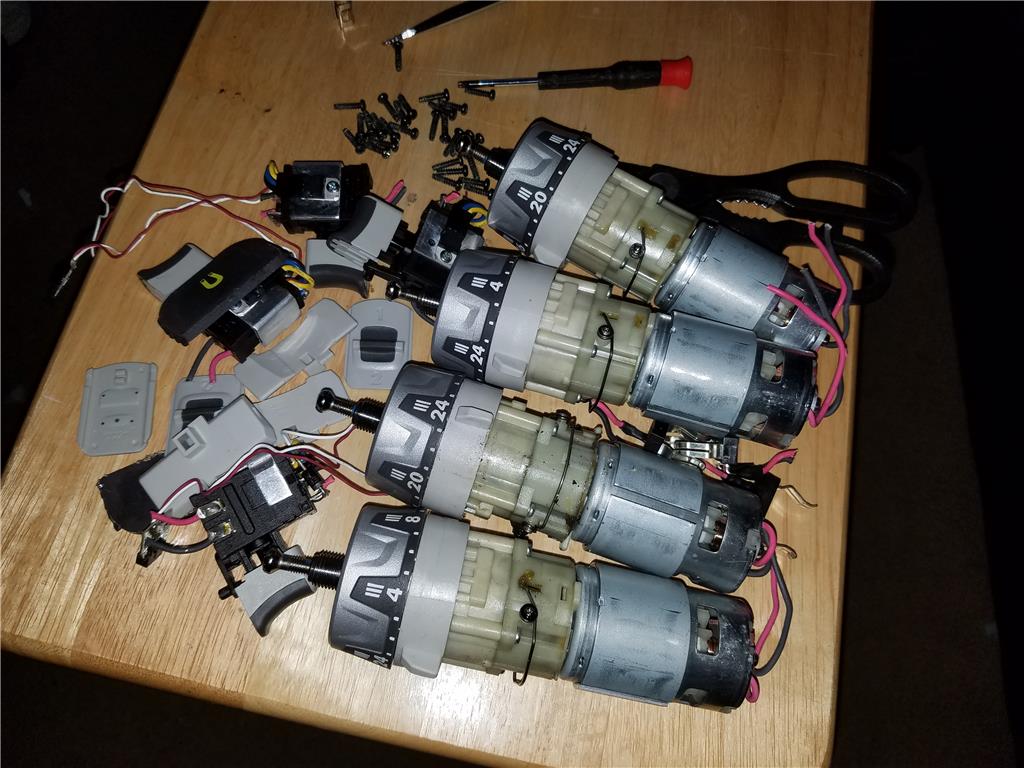
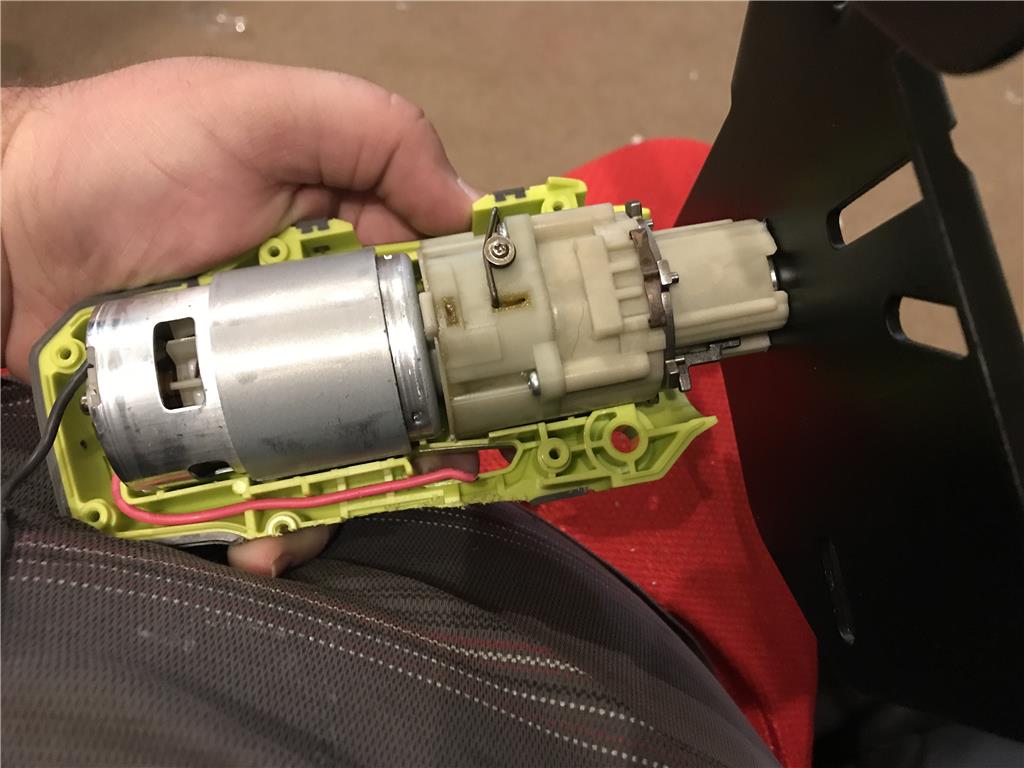
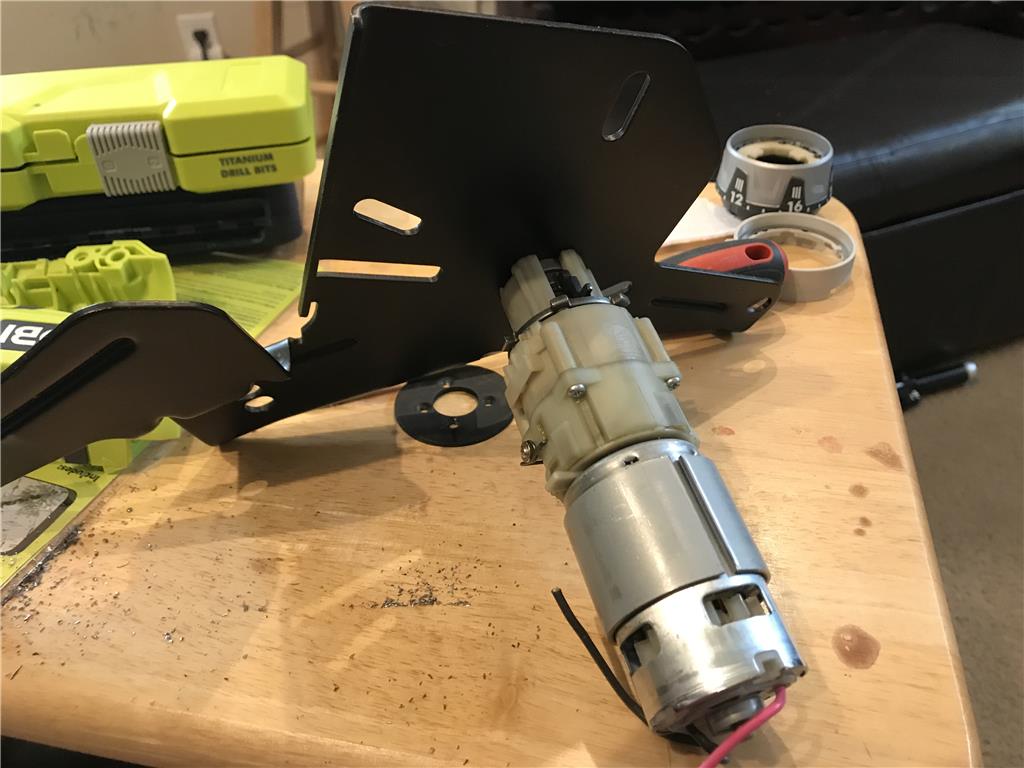
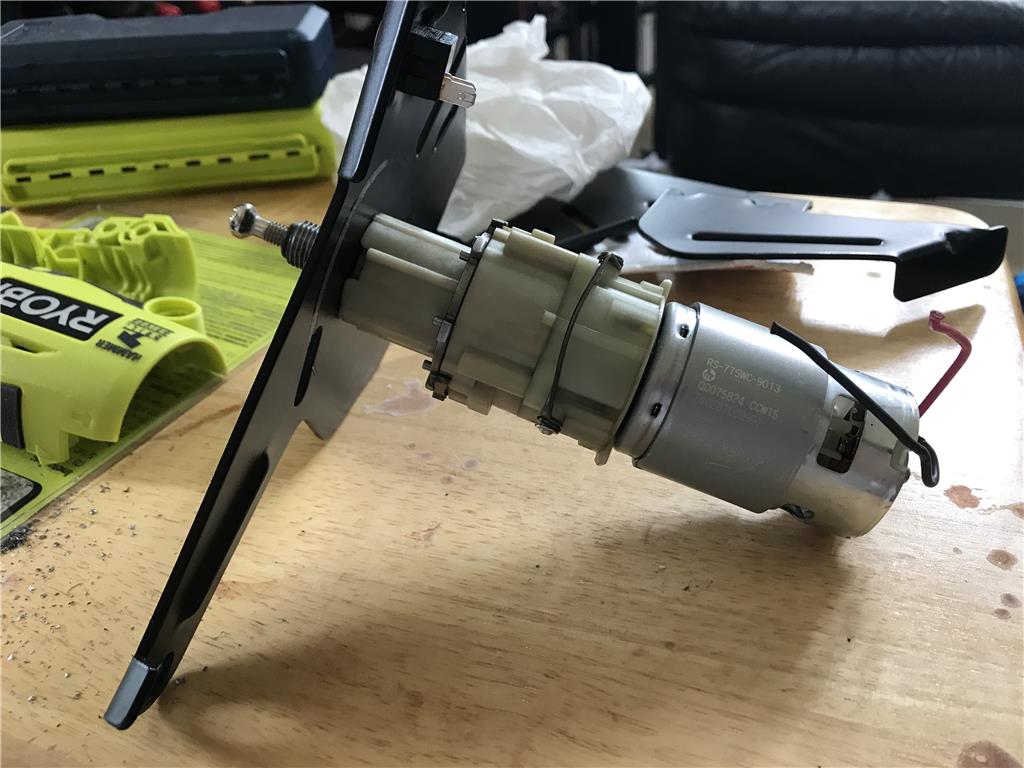
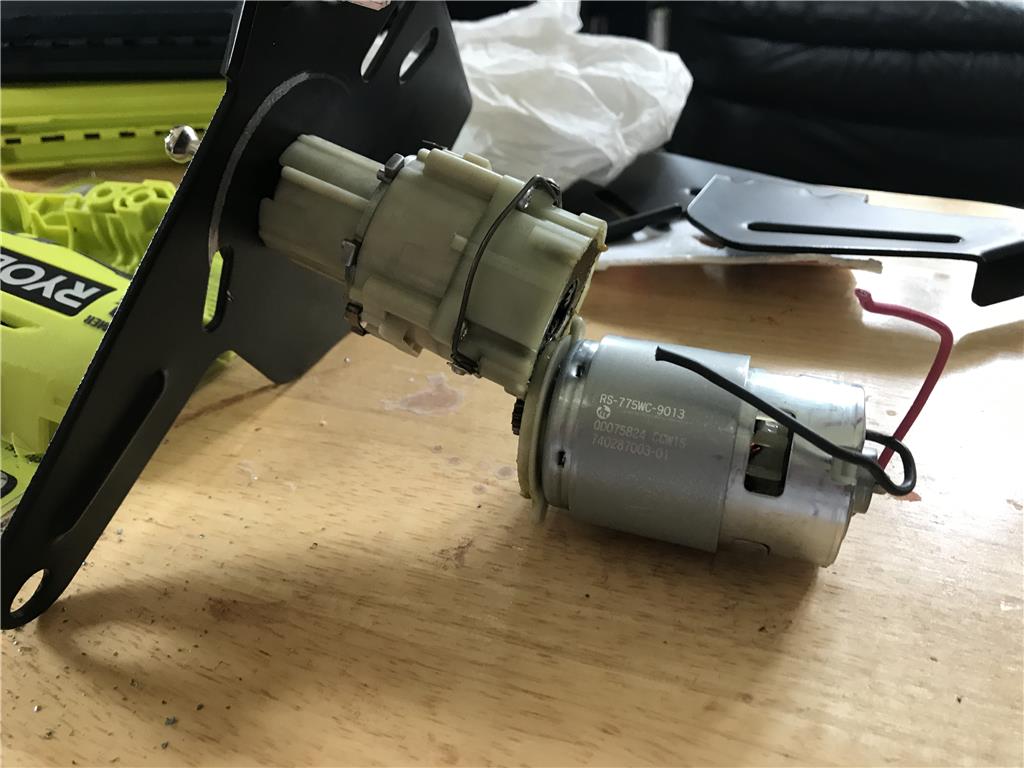
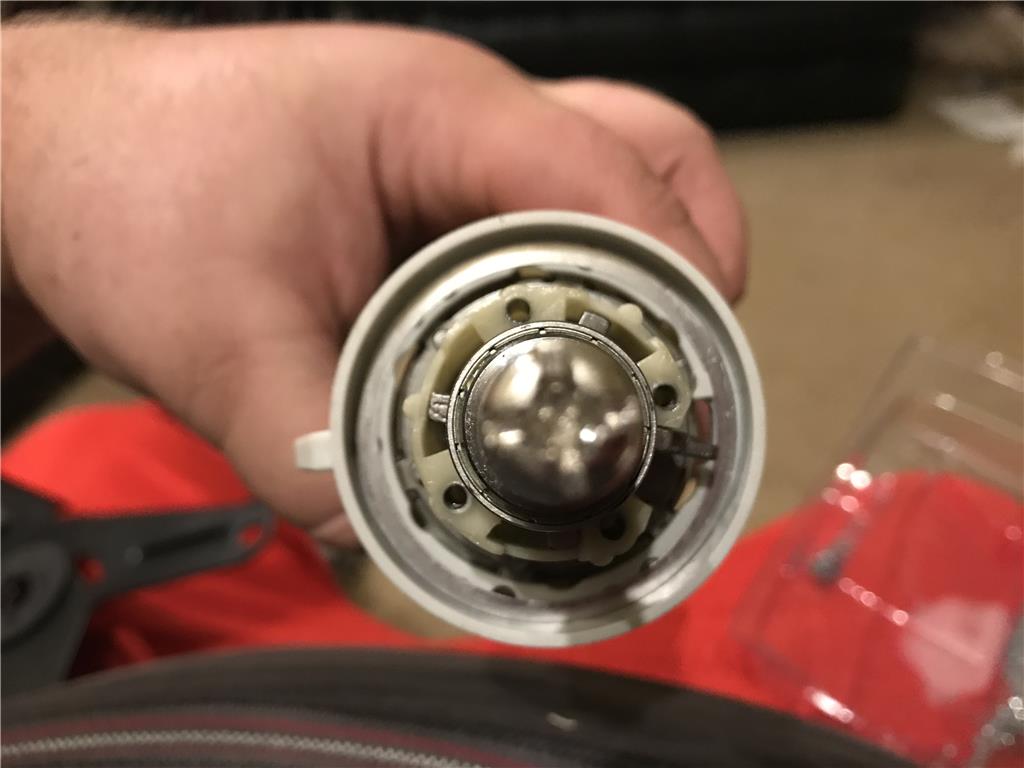
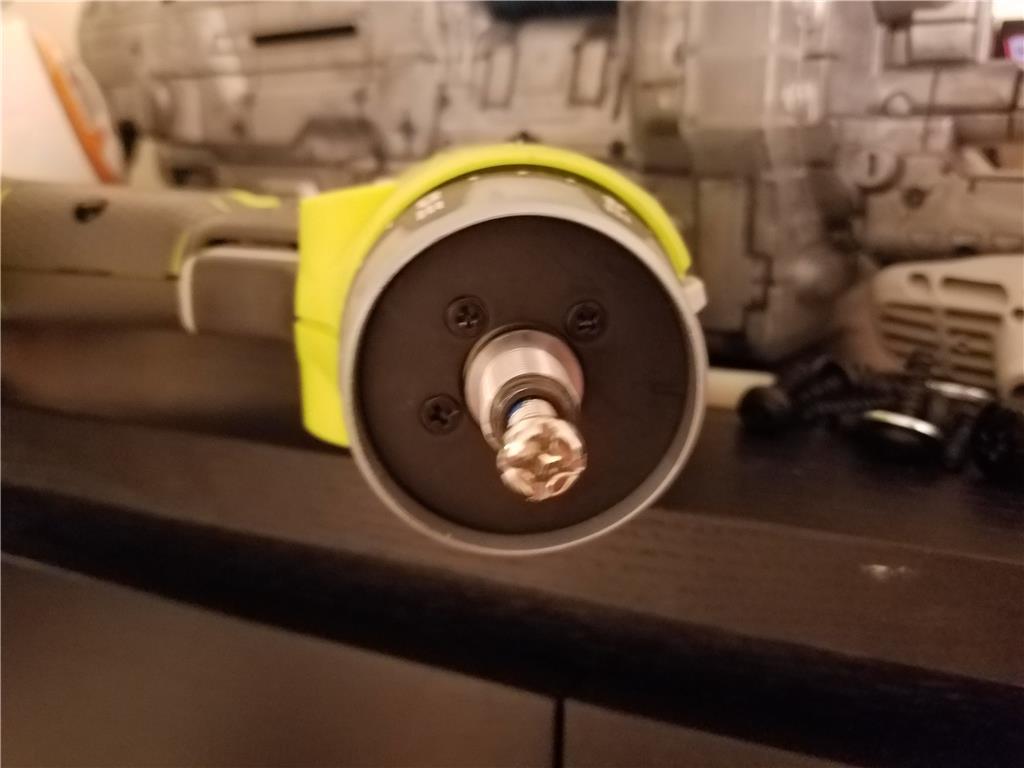
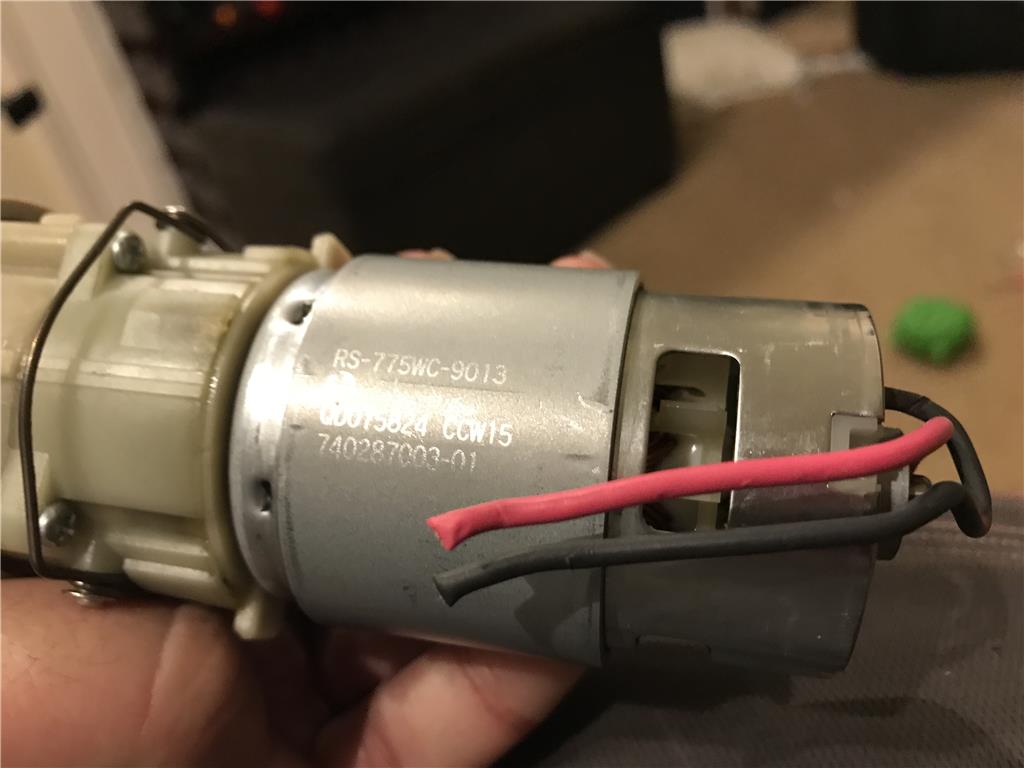
The motor unhooks from the gearbox with a simple 1/8 twist. I believe I will use a portion of the original casing to keep them mated together.
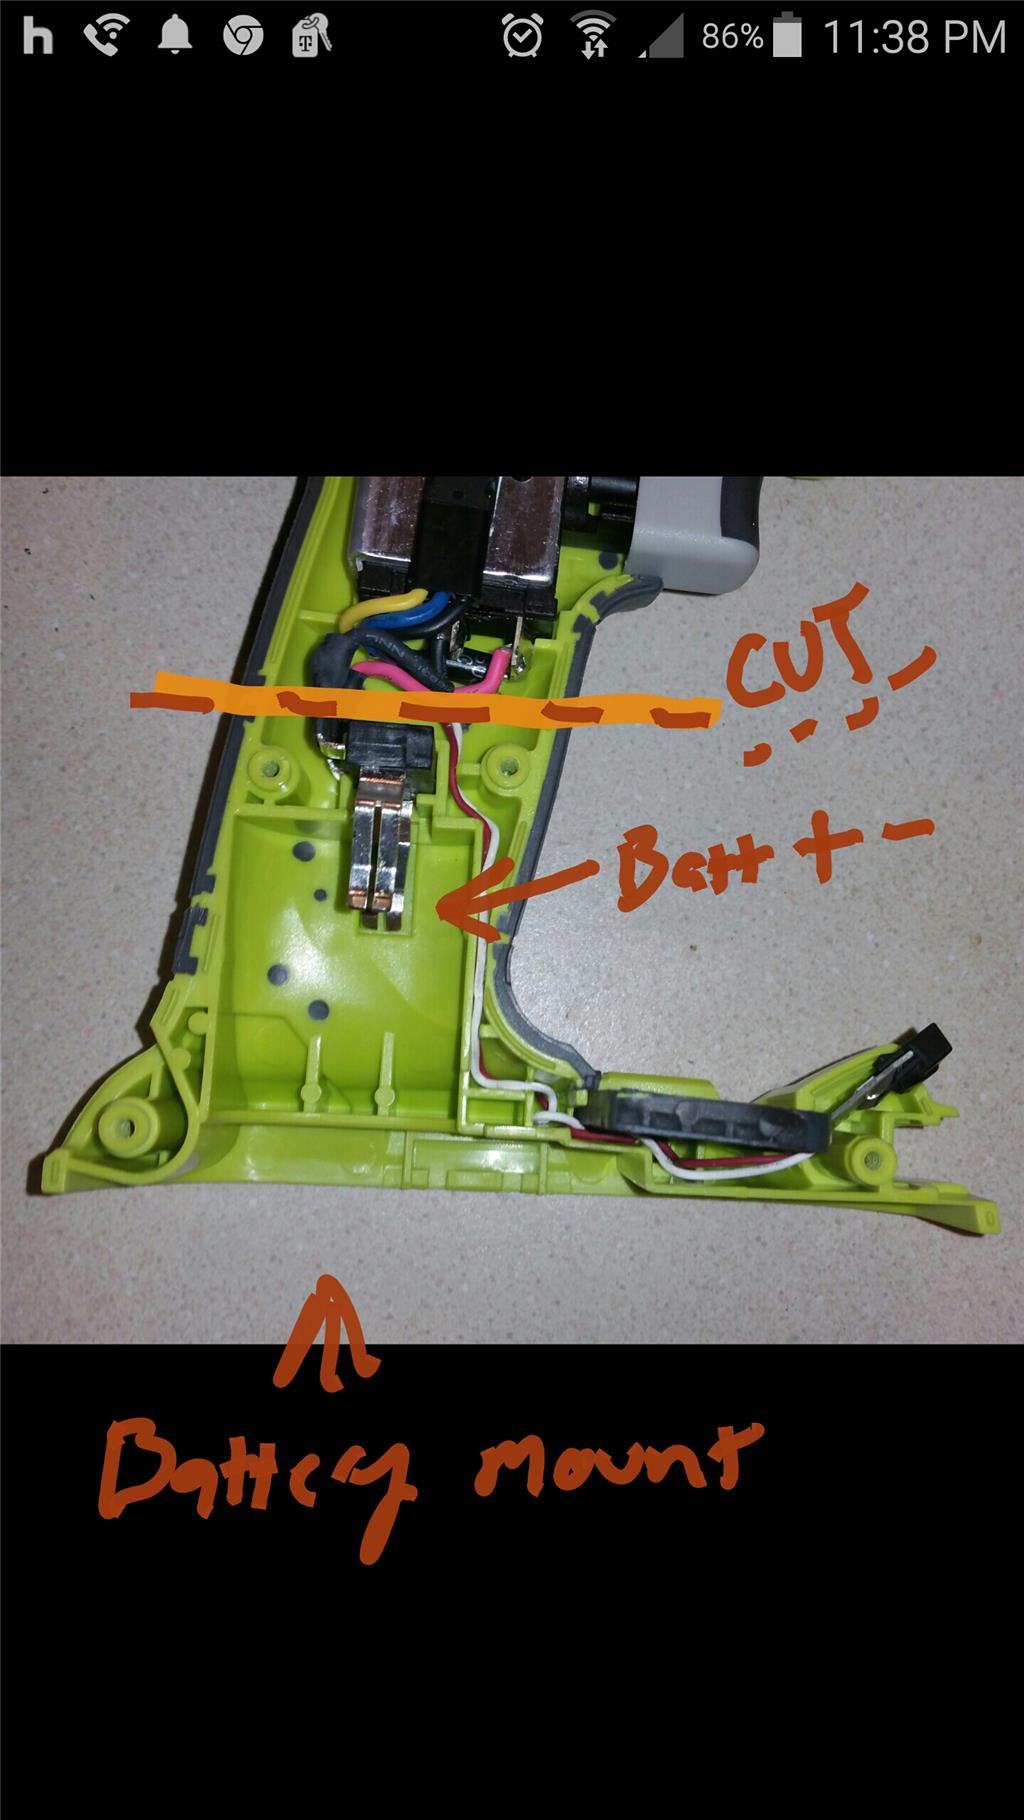
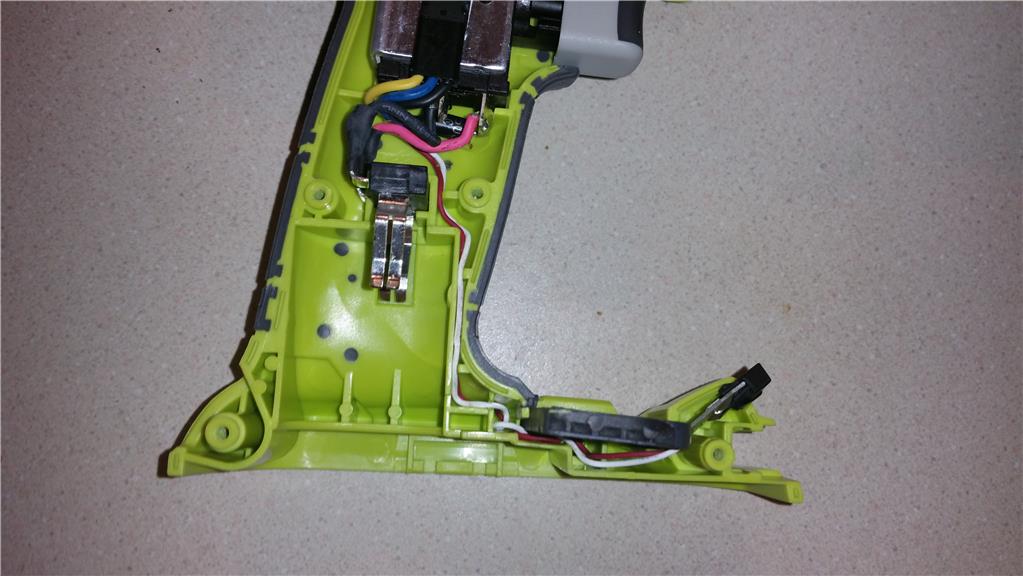
I will add a large hole at the end for the power wires to feed through
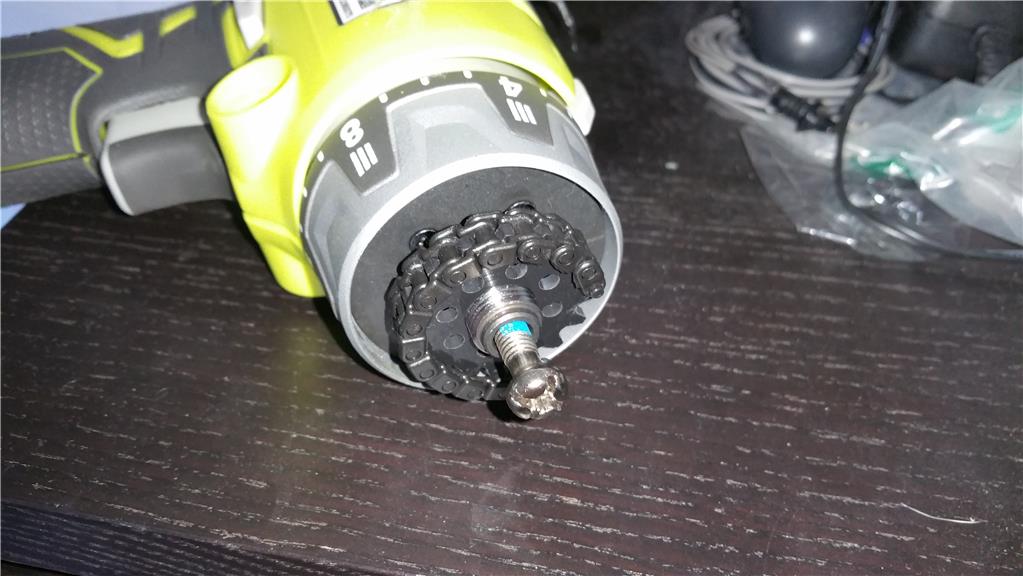
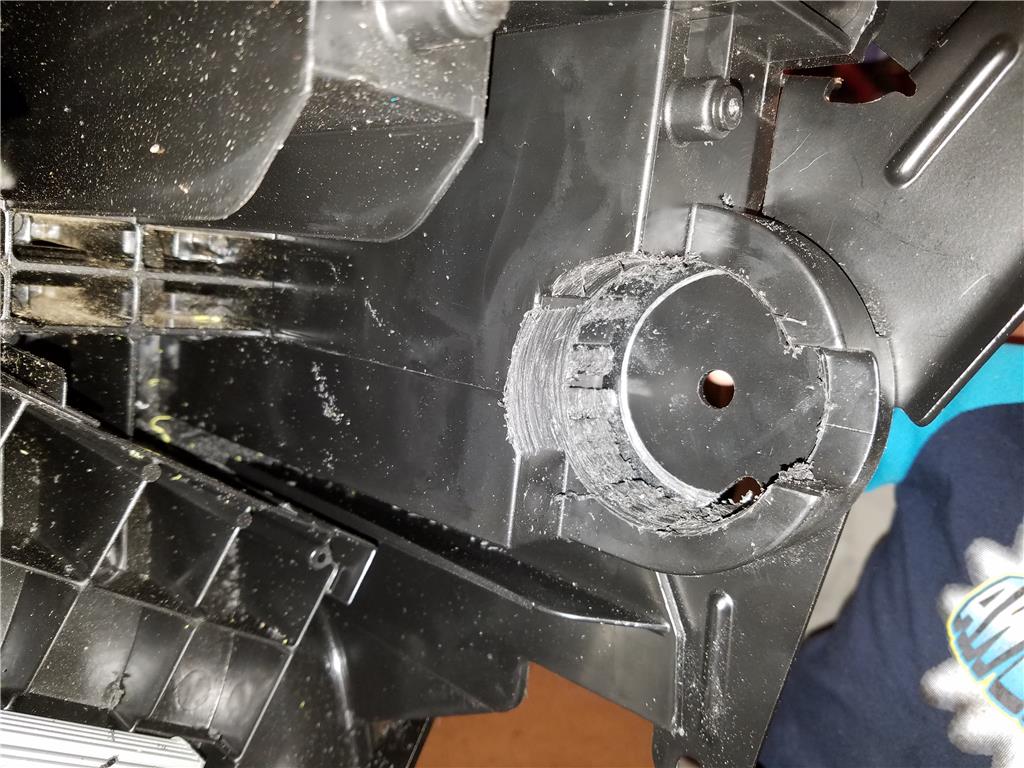
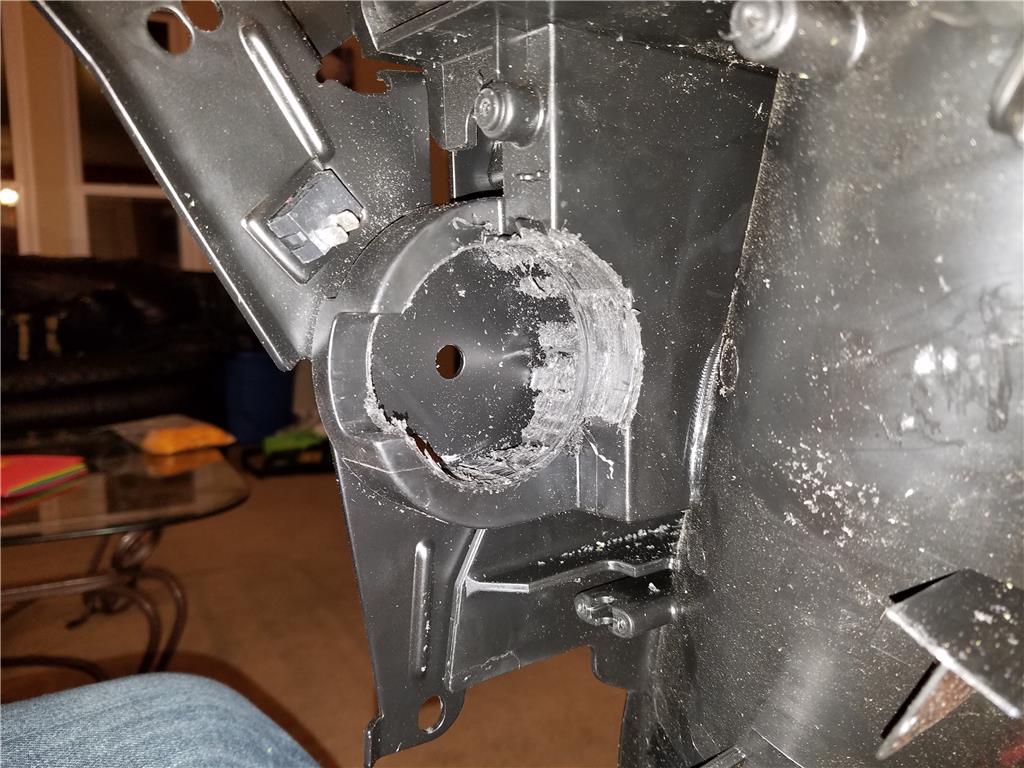
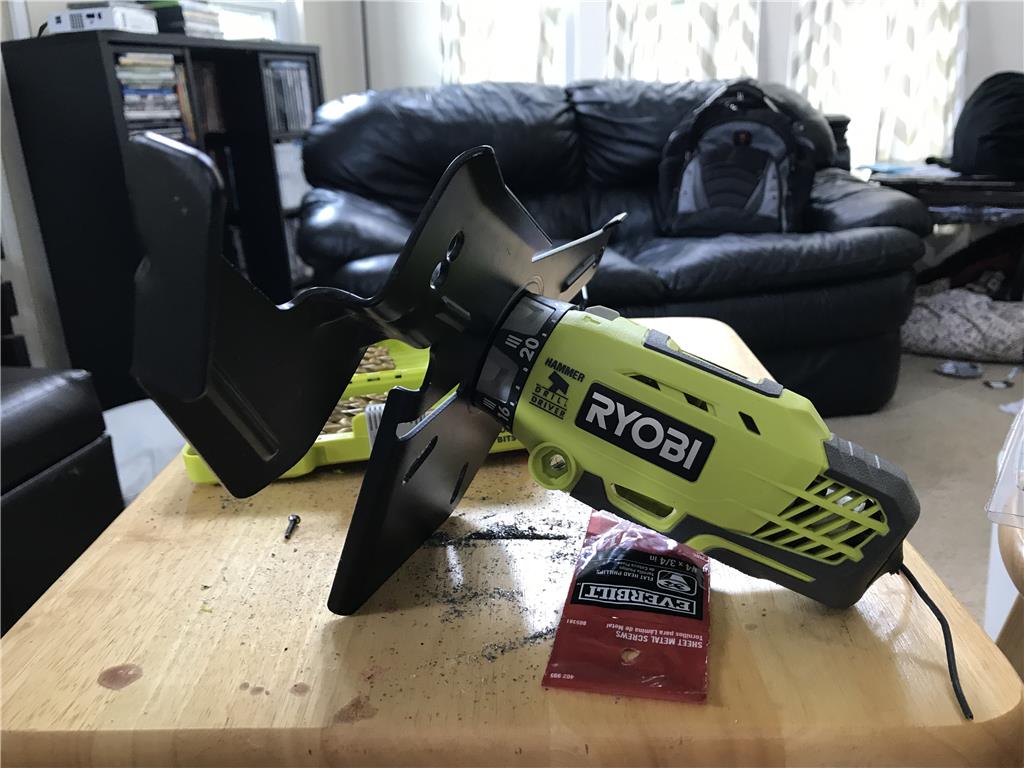
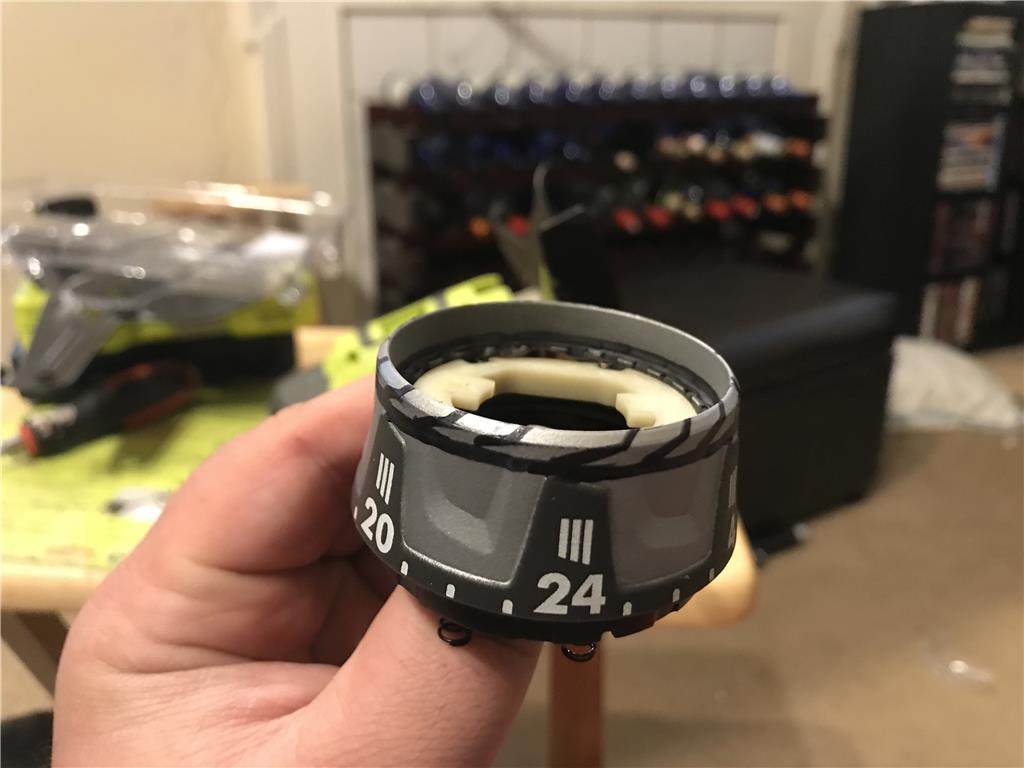
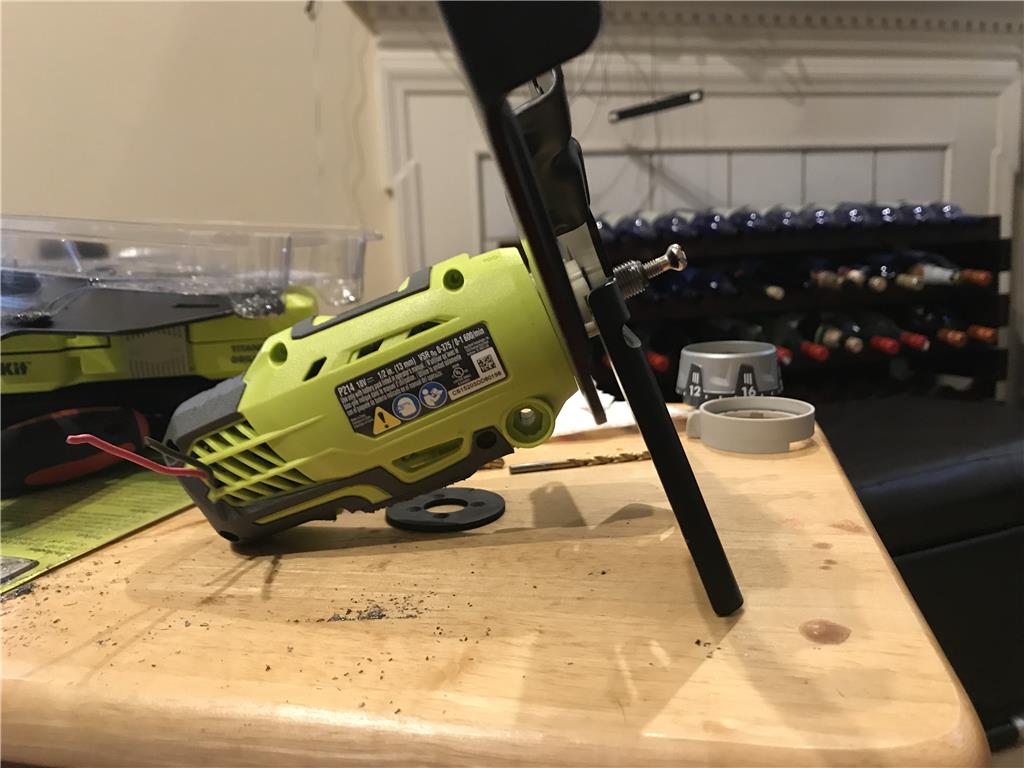
After measuring I found that there is too much plastic lip on the clutch sleeve. I will need to find the dremel and trim down the clutch so that I can fit it behind the metal plate and still be able to screw it all the way down to the face of the gearbox.
On a side note I am going to go find those nail clippers! Those are scary.
Those nails will work well for stripping wire.....
Project is going well. Looking forward to more.
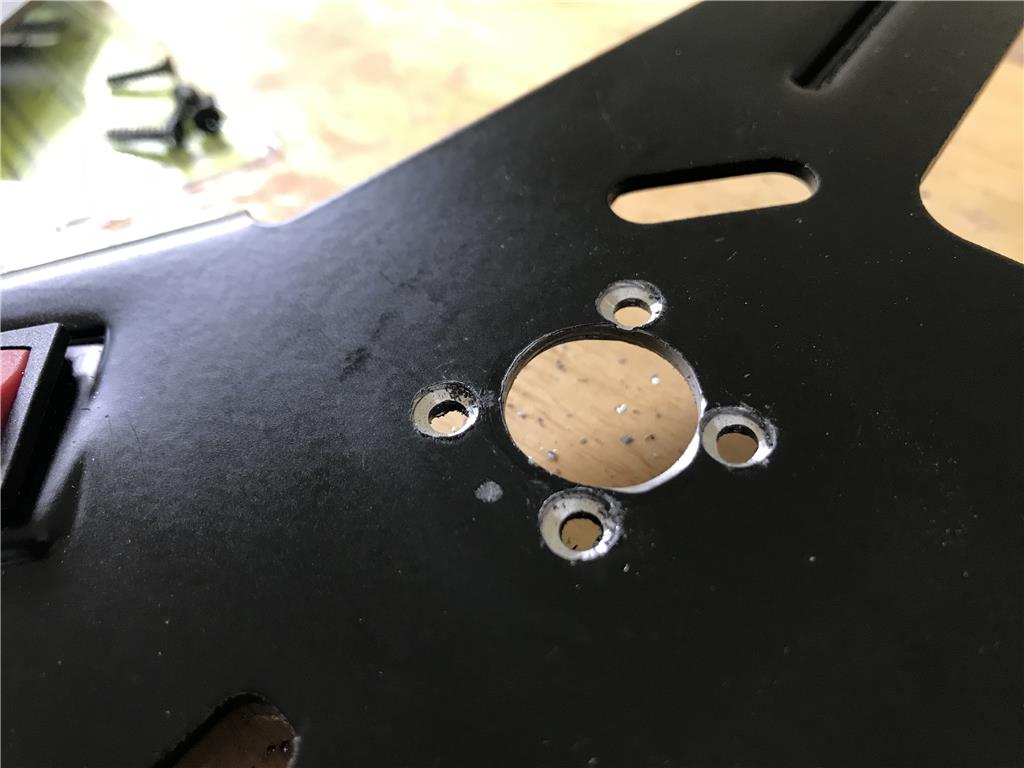
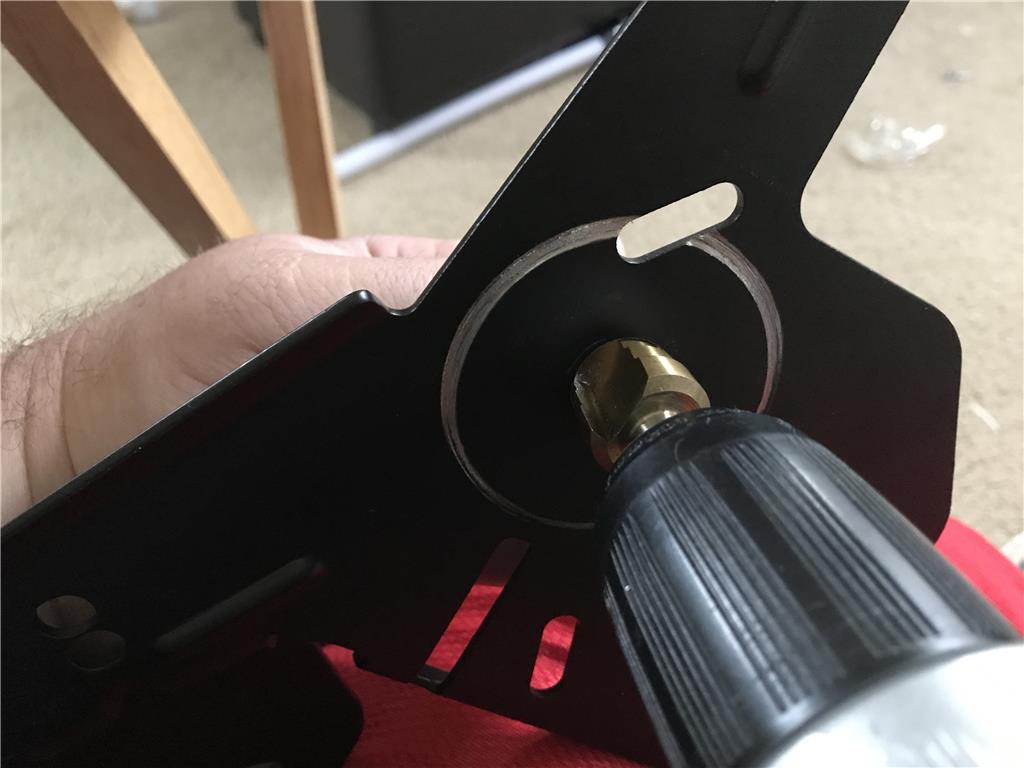
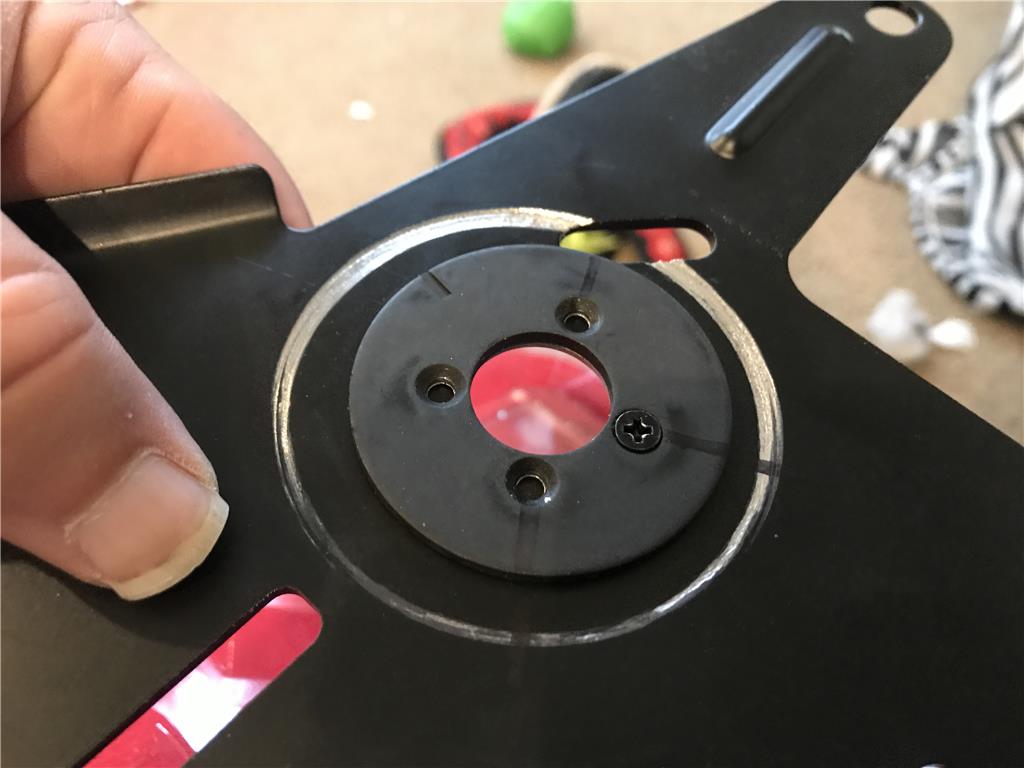
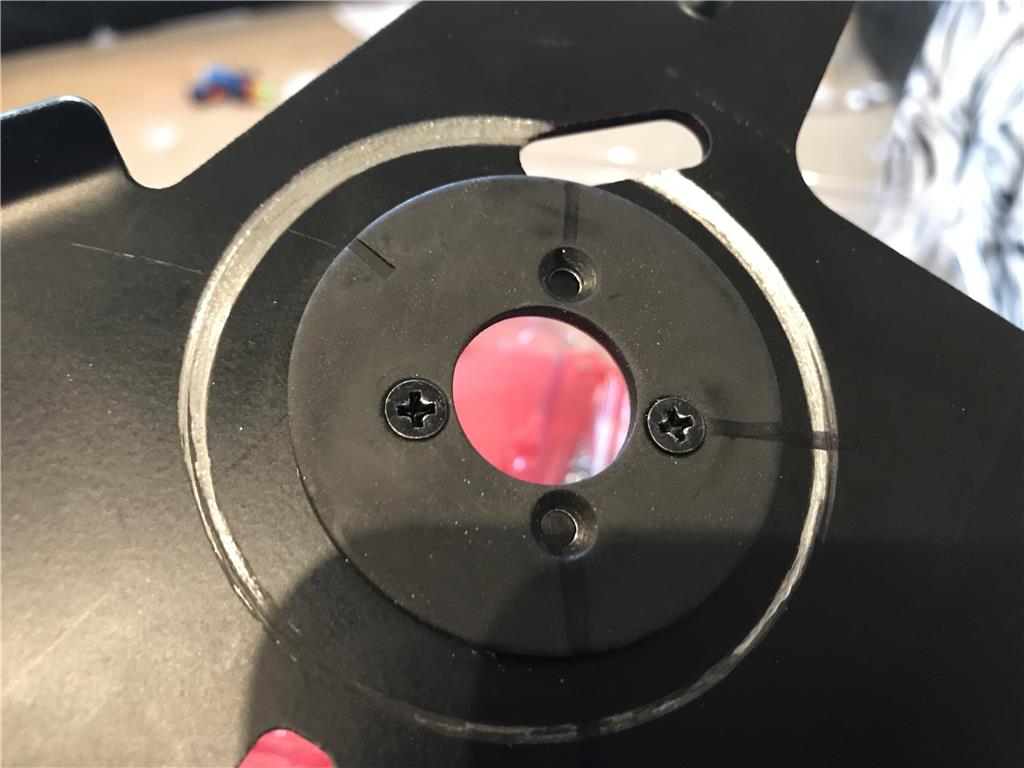
Ok so I used a larger bit and slowly machined out the holes to countersink the screws.
They sink in well now
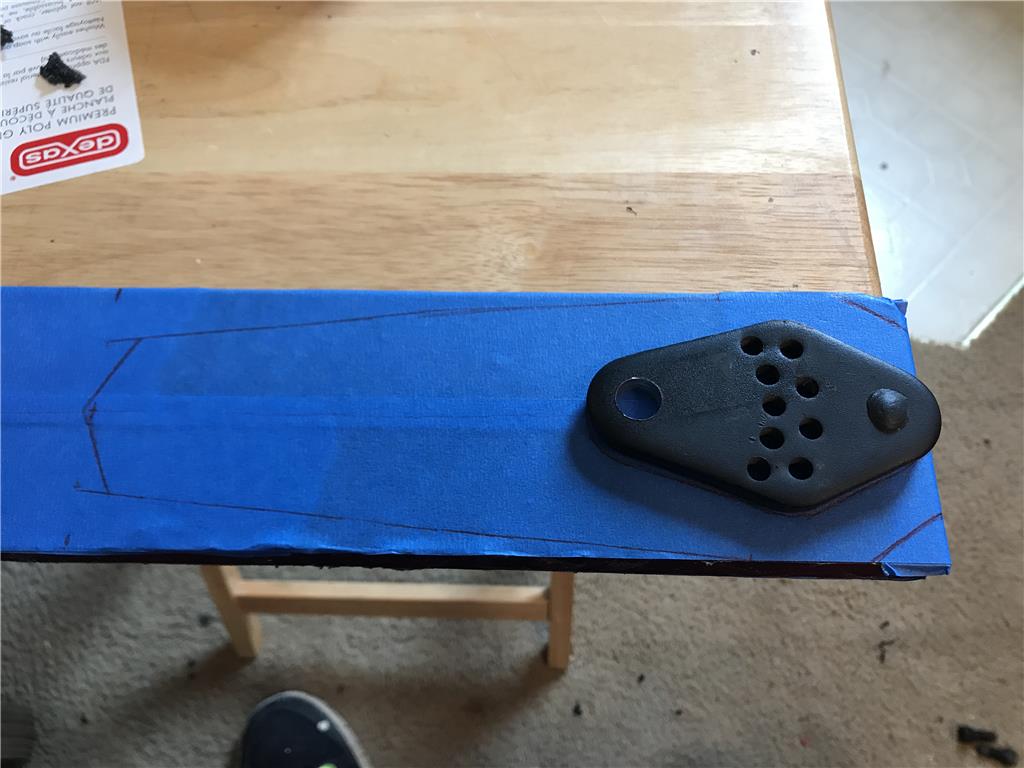
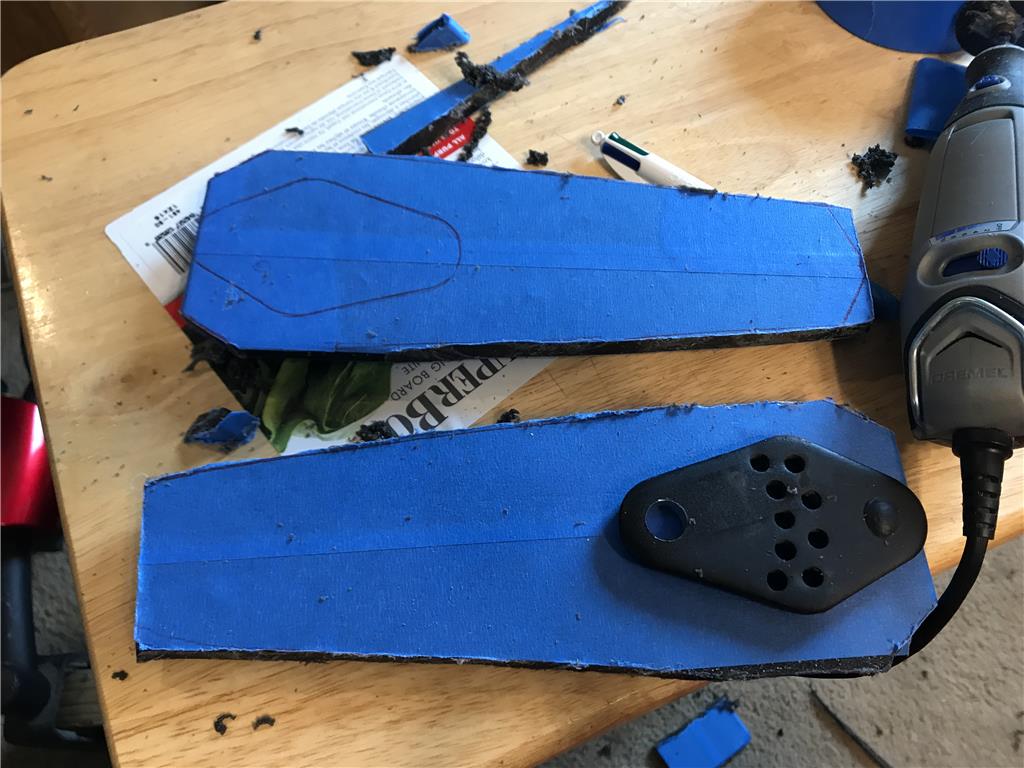
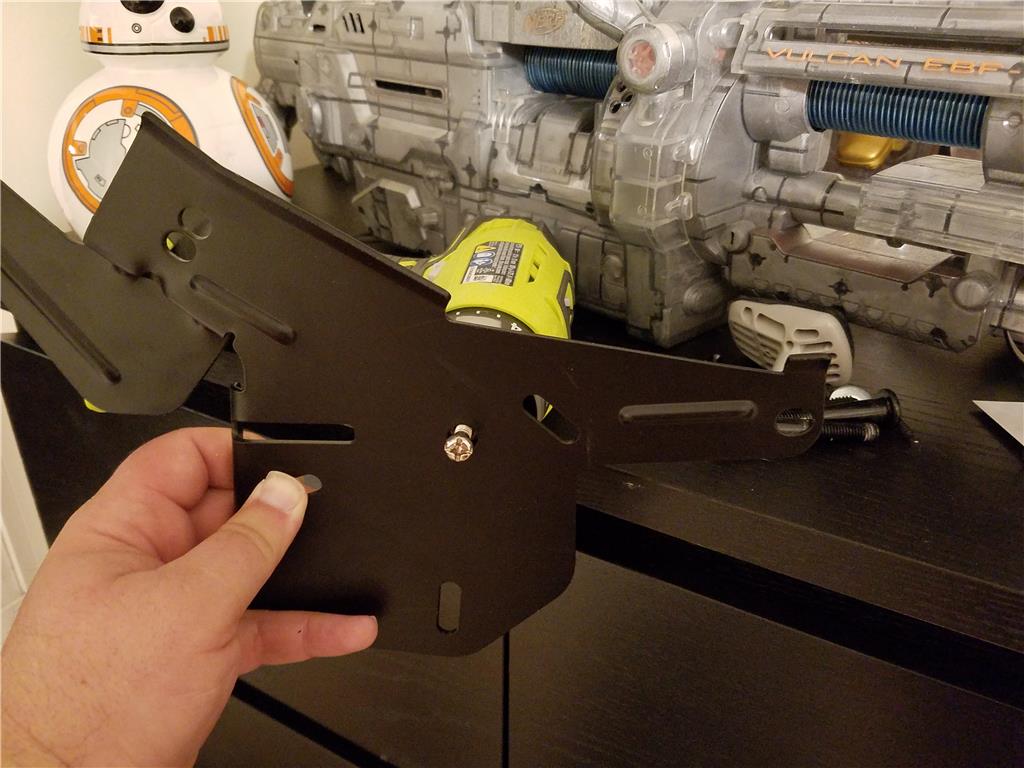
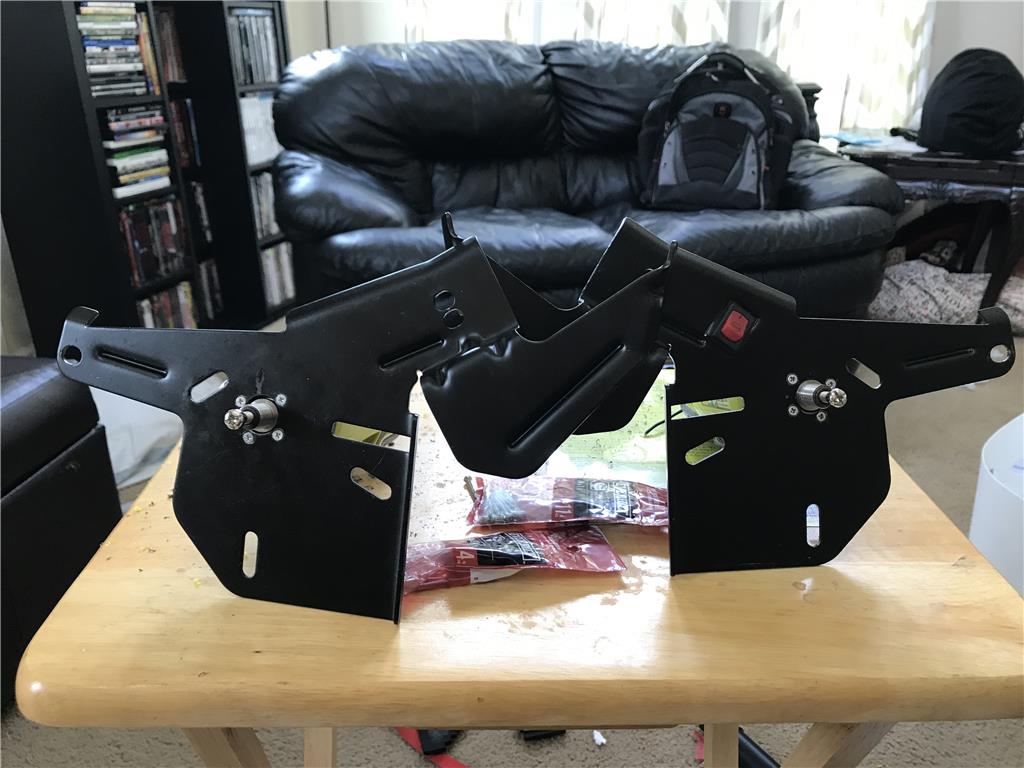
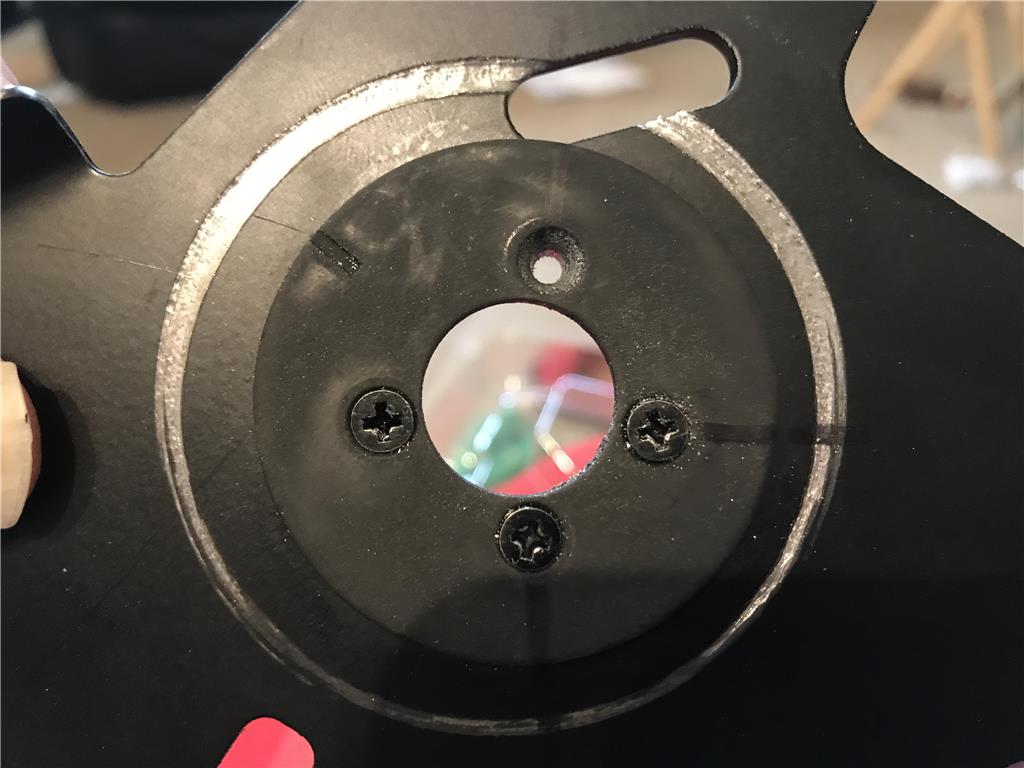
Ok so you are going to laugh but I drilled the pattern from the WRONG side on the left bracet. At first I thought it would be ok till I found the holes are not symmetrical. So I had to make some adjustments. Ugh
You can see they are a couple mm off, it is fixable but I am still grumpy