

Hi all
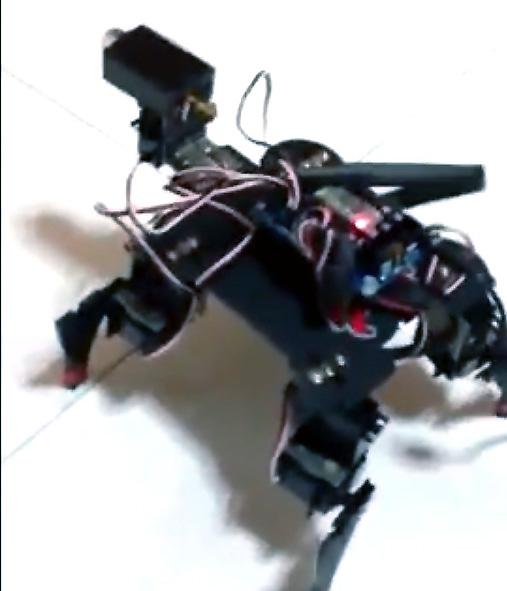
I have a made a new 2 DOF quad.
He is called Crabio 1.
I only have time to add a video about him for the time being.
I will post more pictures soon.
His walking pattern is abit noobish but i will fine tune him later:)
enjoy for the time being:)
By iskandershah
— Last update

Discover more robots
Jdebay's Gripperv4 Old Parts And New Parts
Build Gripper V4 from old and new parts; updated design now includes an added camera.
Rich's Jarvis Add-On #1
Automated direction-aware staircase LED lighting using Synthiam ARC, EZ-B and IR sensors with EZ-Script for runway-style...
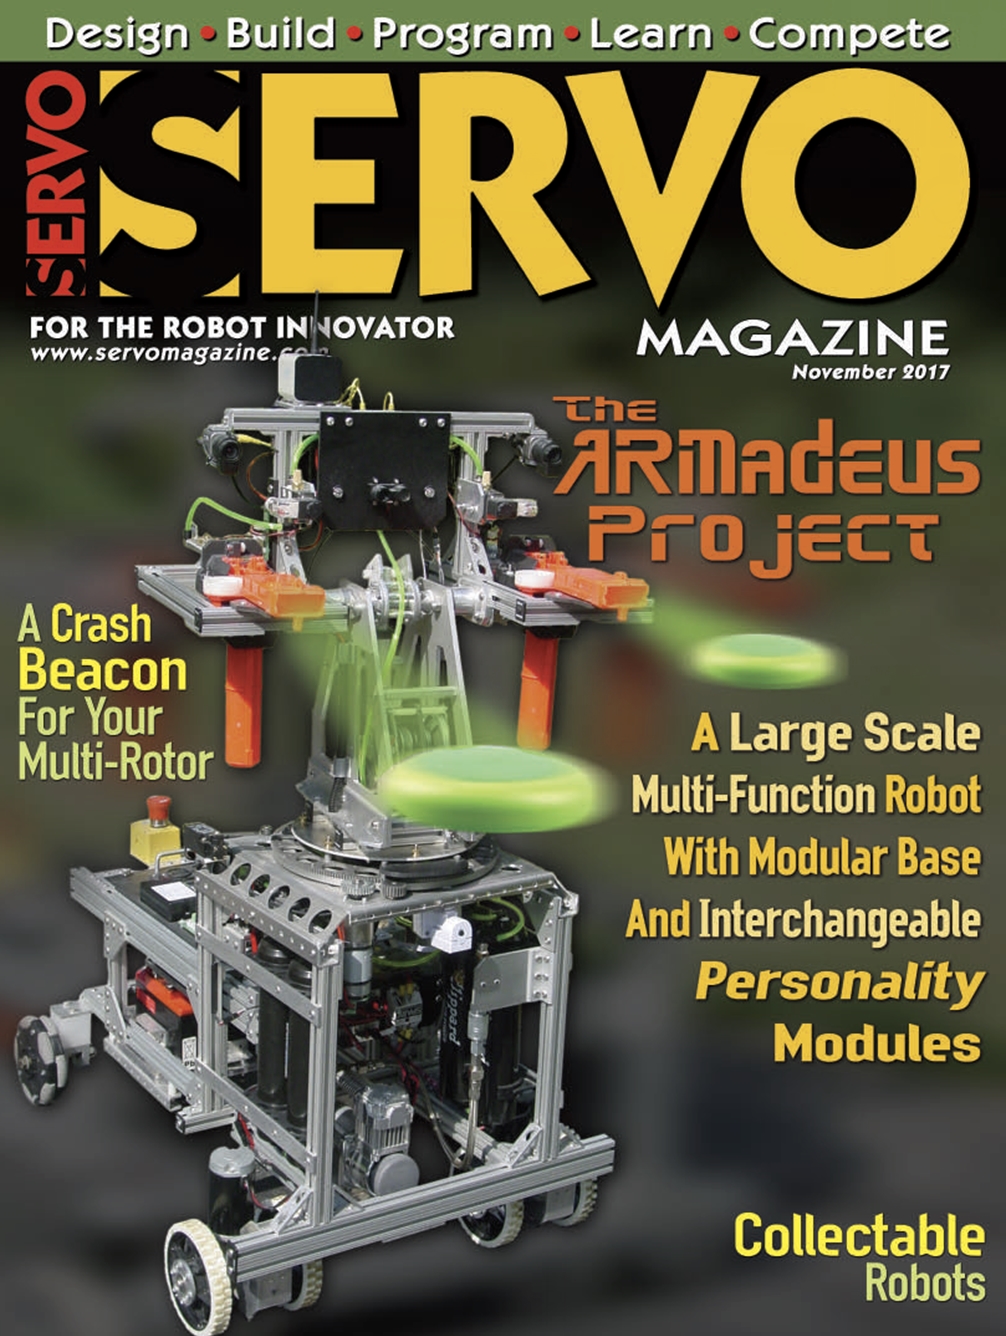
Jim's Armadeus Mk. 11
ARMadeus Mk.11 - 140 lb modular robot with EZ-B v4, universal base, interchangeable turret with dual pneumatic NERF disc...

Looks Great!
That is awwesome!
Just love seeing different things to wheels for moving robots around. Those legs may not be very efficient and appear a bit creepy but they give the robot real character - great job
yes you are right, the legs are too heavy for a small robot like carbio, so i did my research and shortened his leg. Now he can reverse, turn and walk.
While uploading the video for Carbio, I just tweaked the code a little and carbio can now stride faster then his normal speed.
Soon he will be chasing red balls:)
Btw Carbio wishes to say hi to All EZ Bians!
This is truly one awesome bot!
Thanks Bret.Tallent
Iskandershah - The way your robot Crabio has 2 verticle positions is very cool, great progress on how he moves around on those freaky legs - Love the camera position - Great stuff and fun to watch