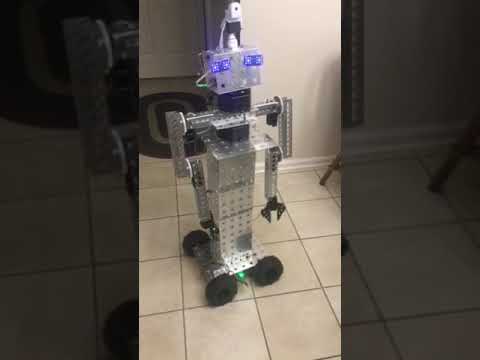
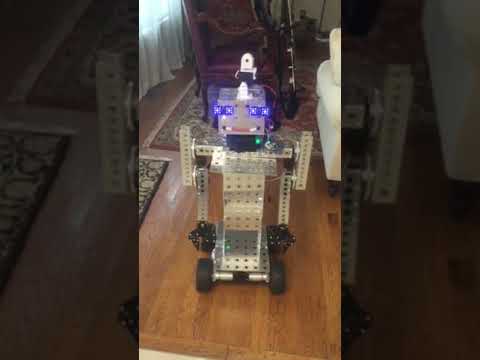
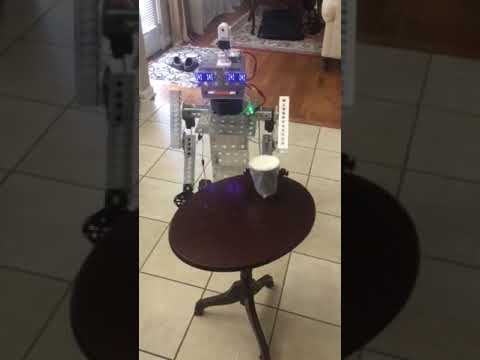
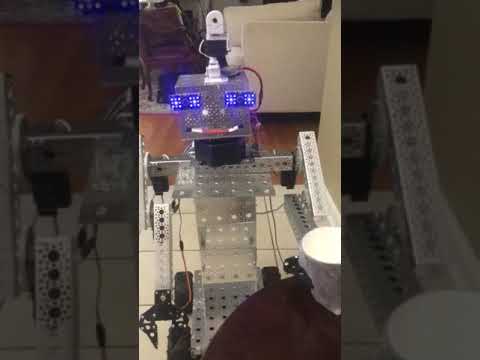
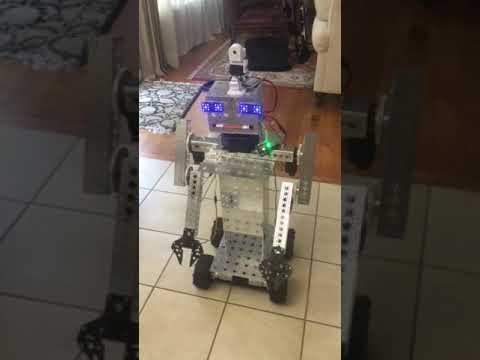
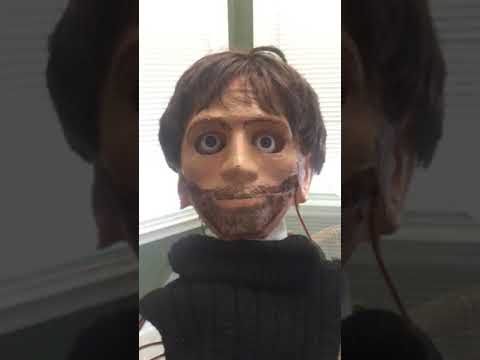
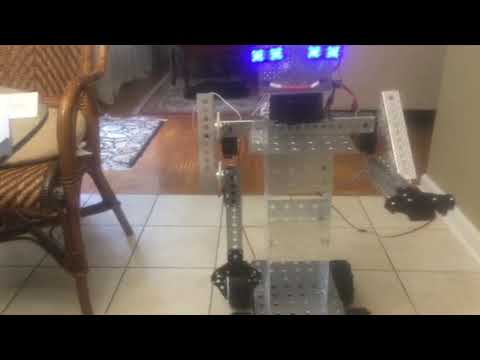
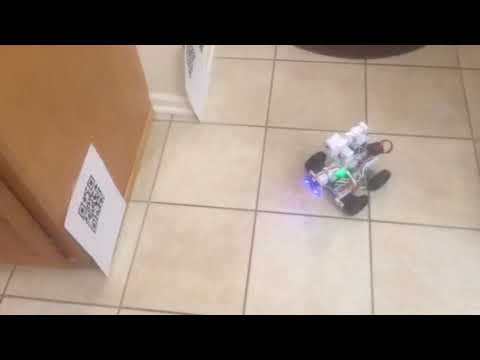
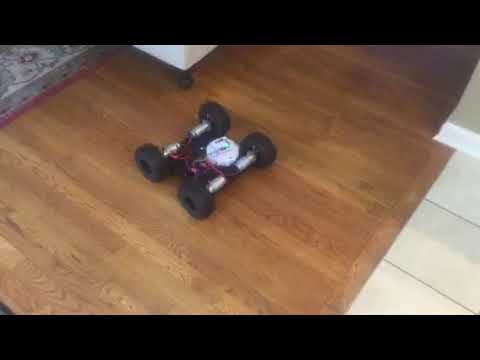
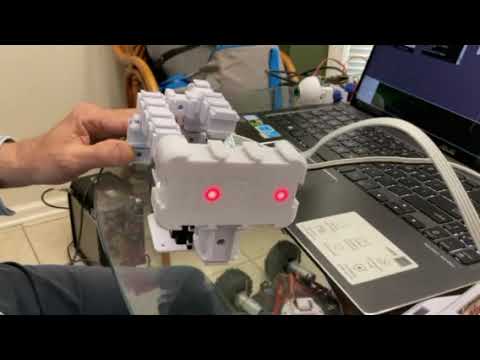
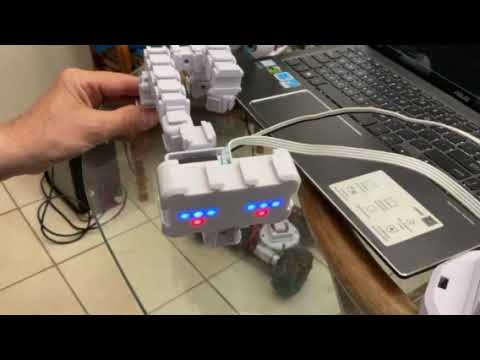
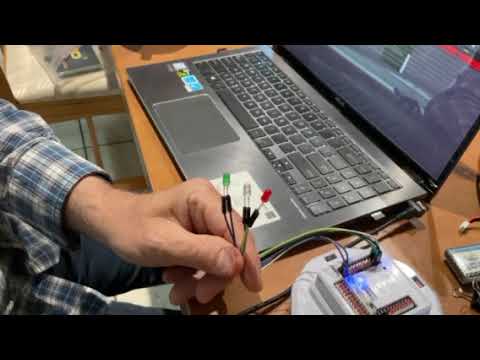
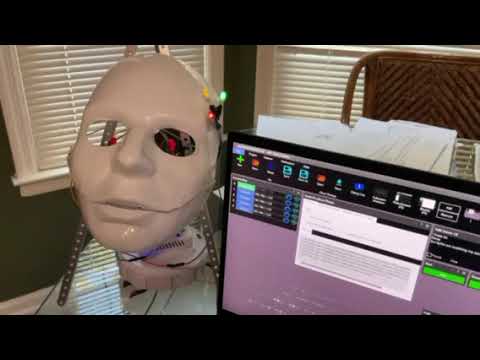
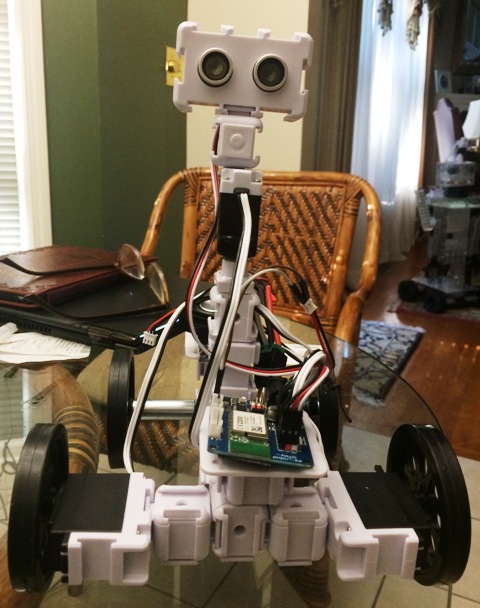
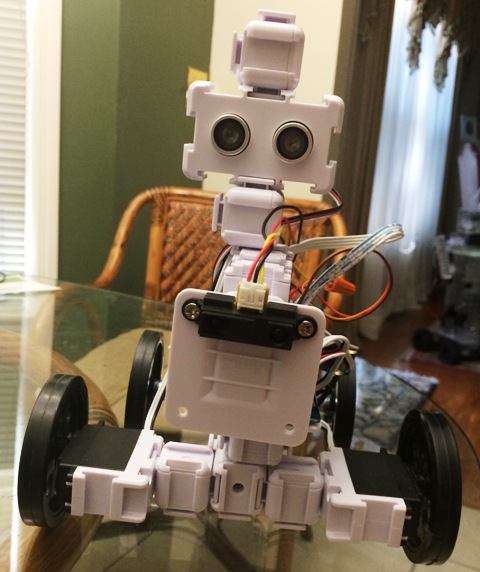
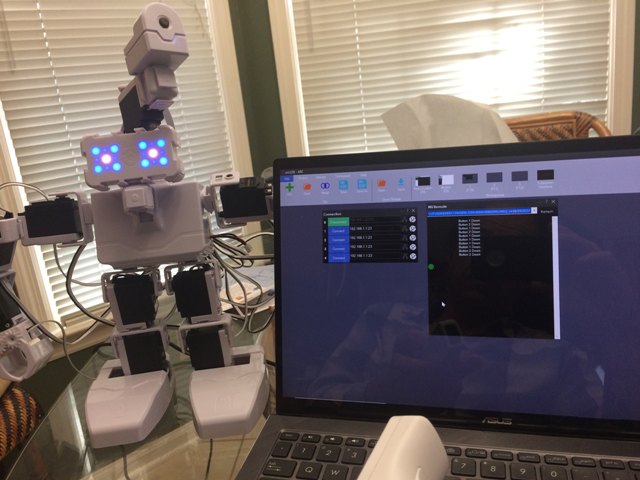
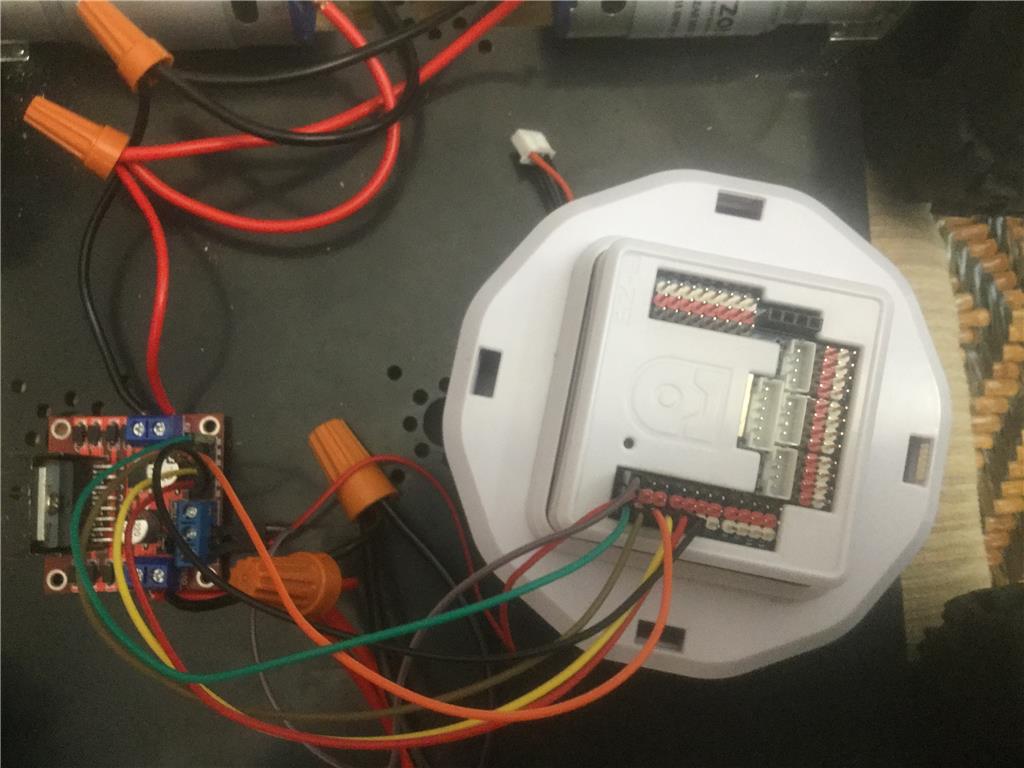
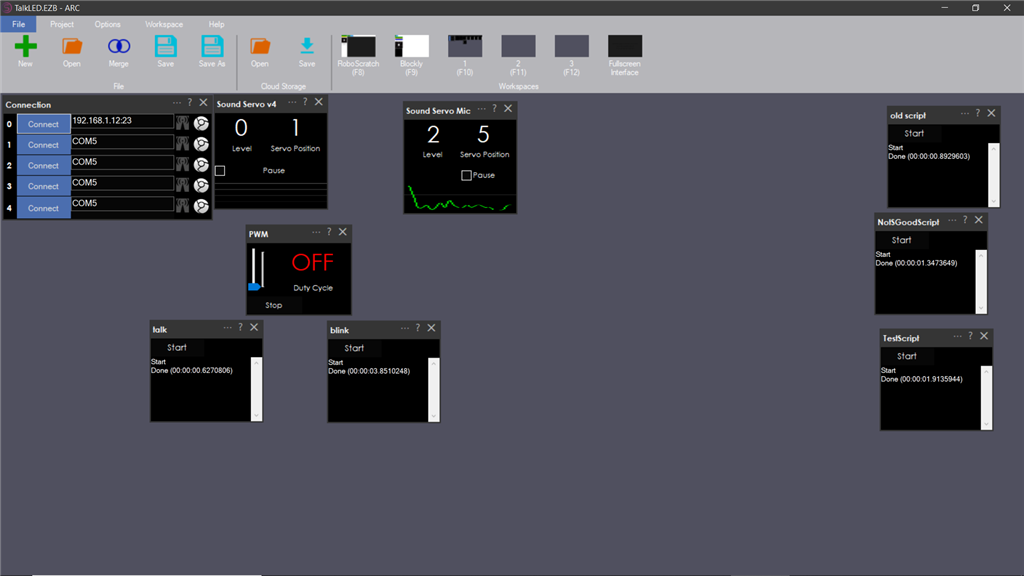

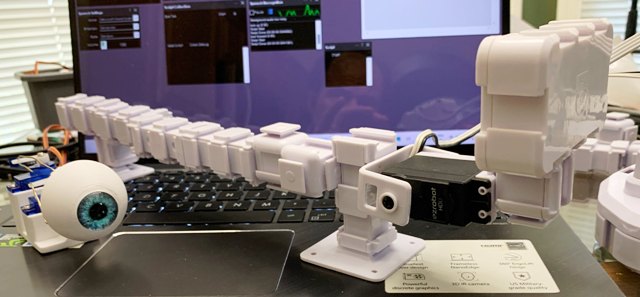
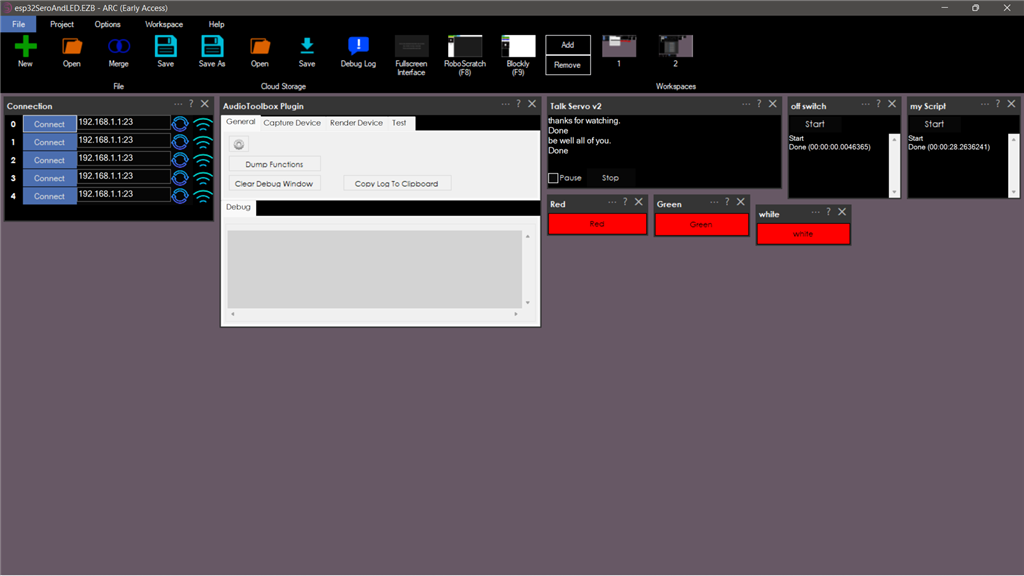
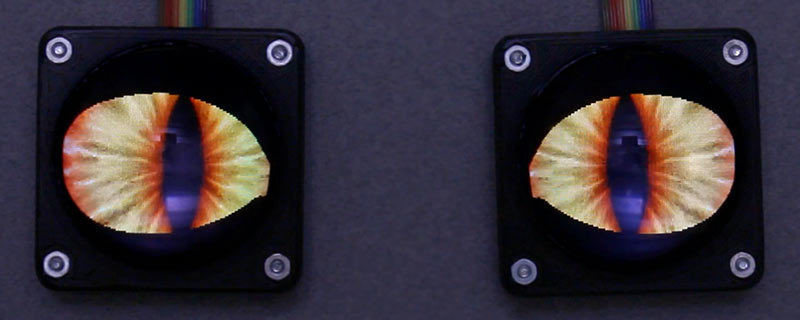
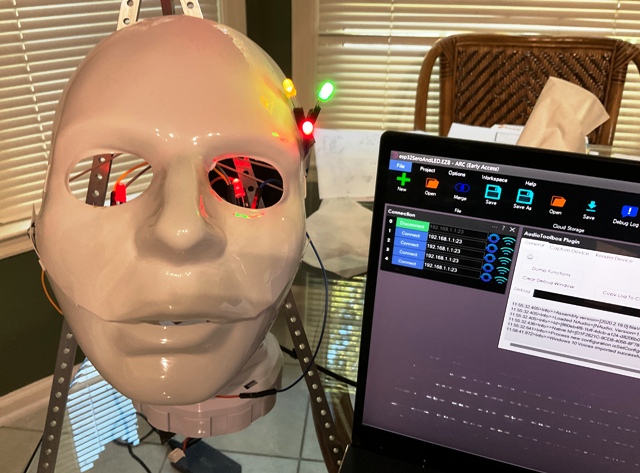
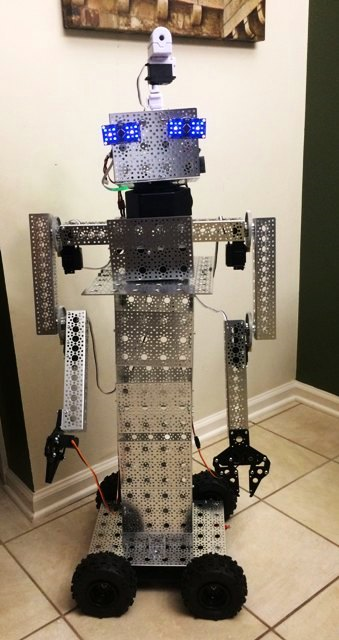
I am using ARC software with 2 iotinys controller, 2 EzB4 controllers - 3 EZ-ROBOT 1300 lithium batteries for the four Ez 360 HDD servos for the two arms, two 996R servos for the grippers, 2 DFRobot rotation hex bases for head movement and body movements. with 2 EZ-robot servos HDD, 2 RGB for the eyes - EZ-Robot HDD servo and moving camera - still need a mouth
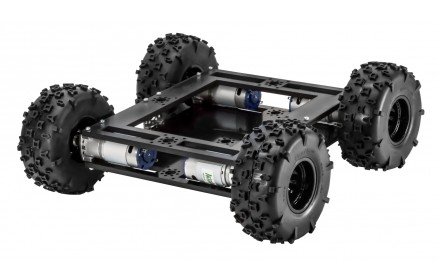
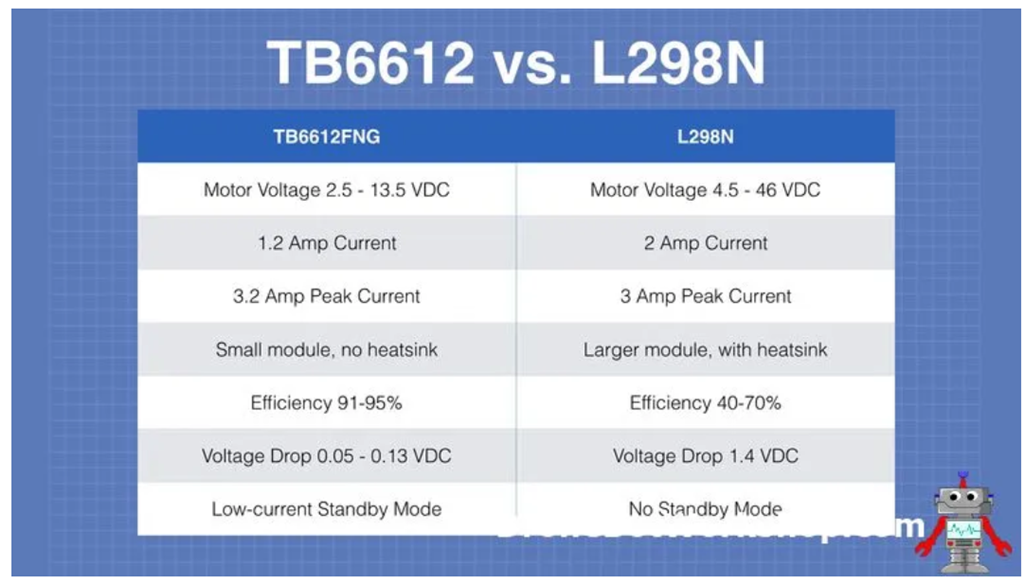
from servo City: 4 gearboxes , channels, parts, extensions, Prowler Robot Kit (wheels, 4 motors, h-bridge pwm motor controller
Here is a sample video
EzAng
By EzAng
— Last update
Discover more robots
Cardboardhacker's M2d2-The Diy Miniture R2d2 By...
Build an R2-D2 replica from a Lysol wipe container using cardboard, servos and a ping sensor, finished with paper-mâché...
Tmesserschmidt's Meet Robot Betty9
Betty9: a 6' tall fembot with servos, blue eye LEDs, Arduinos, EZ-B and Echo Dot, mounted to a hacked Segway MiniLite...
Mitzeljk's Meet Modi
Modi mobile voice-recognition robot controls a computer via EZ-B scripting and H-Bridge, built on an RC car base from...

have a great time printing.
hi ezang
finally got the sound servo workin.
another error i found in the stl is the eye touch the jaw hings.

need to fix that.Good morning all, welcome to my thread.
how are you?
First day of "fall" here in the USA- Tuesday - 9/22/2020
Had many things to do yesterday here, a few things to do today, maybe I will get to printing today, oh well ---- ever feel "life" gets into the way of what you want to do, lol
We will see what what we will get into today.
EzAng
ezang
problem solved jwa contacting the eyes.
waiting for parts.
Good work Nomad,
EzAng
hi ezang
here i modified the main gear for turning the head.
looking good, nice movements, LEDs good touch - keep it going
So many things to do here, still never got to concentrate on printing.
EzAng
off for a long weekend, be back Tuesday the 29 of Sept. for a while.
All be safe!
EzAng
just helped in Speech Synthesis: check it out
https://synthiam.com/Docs/Skills/Audio/Speech-Synthesis?id=16117