


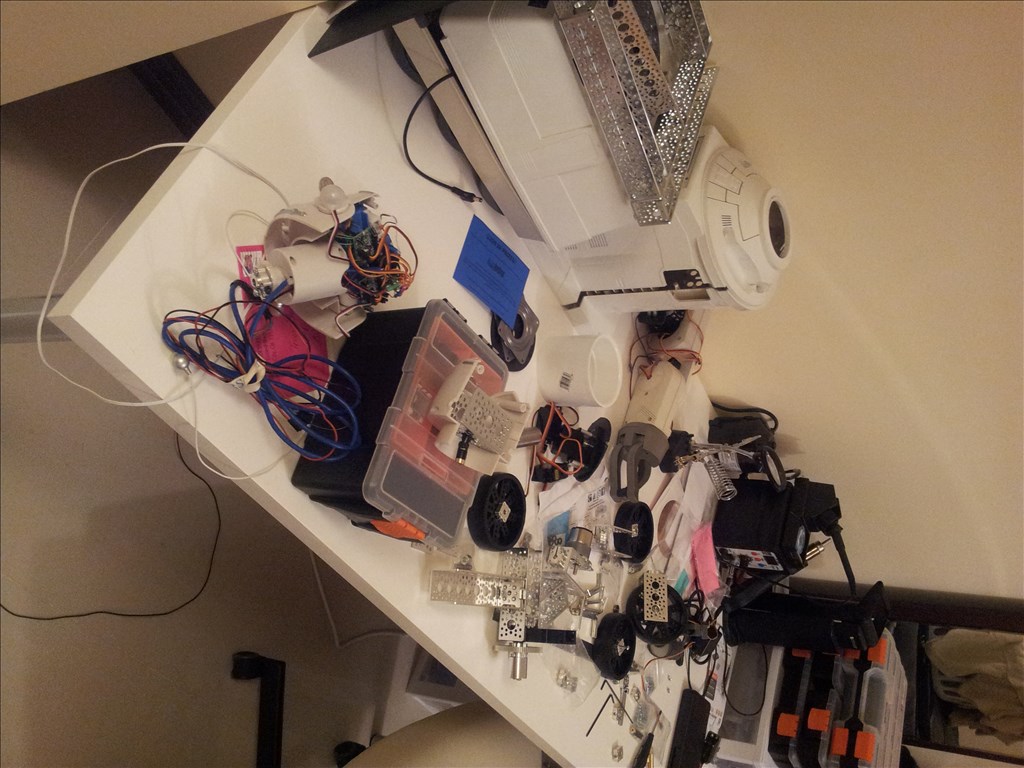



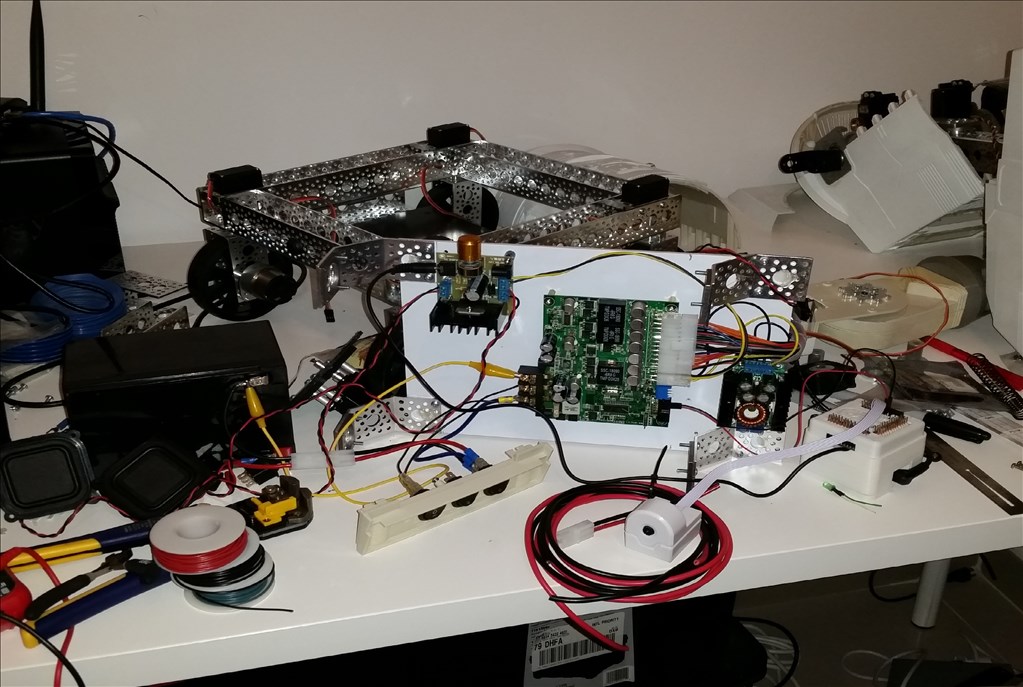
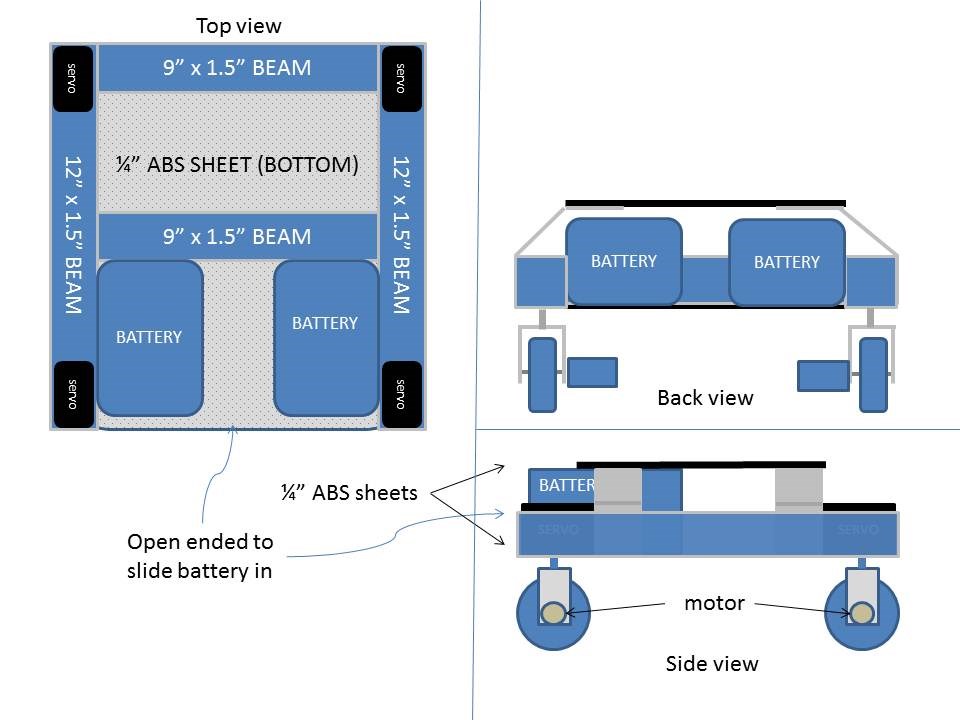
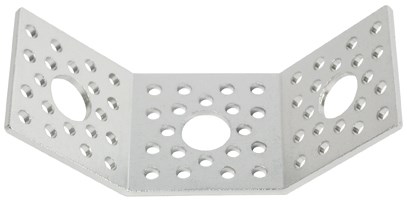
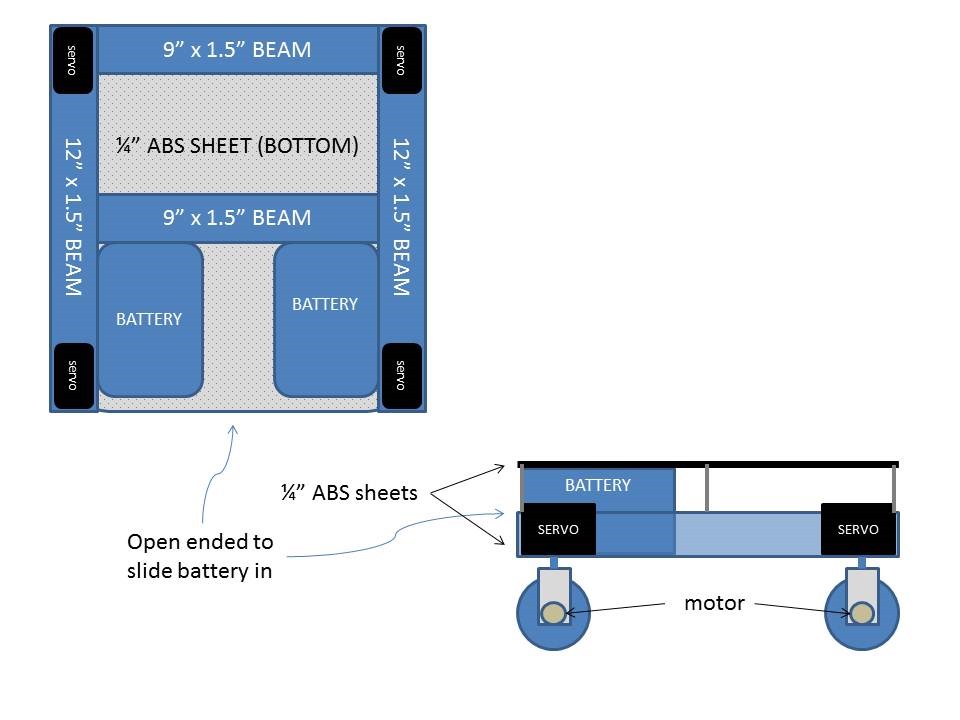
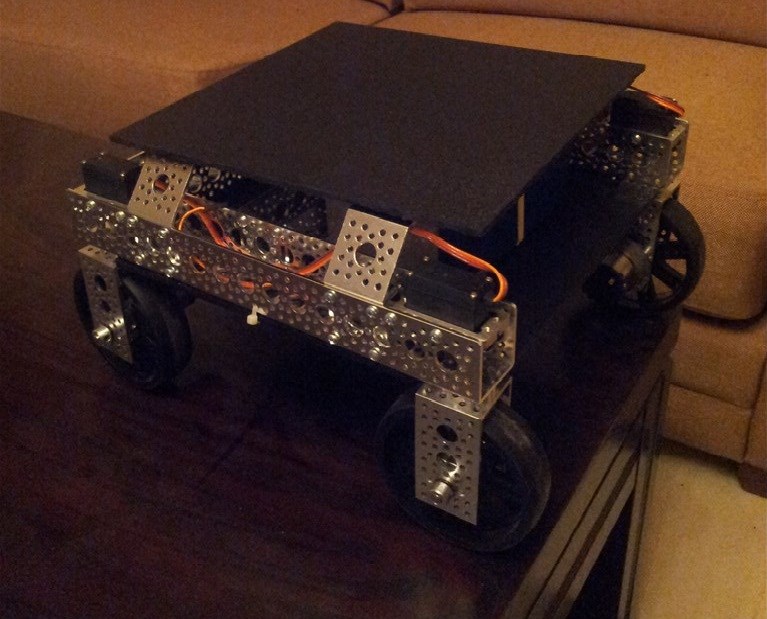
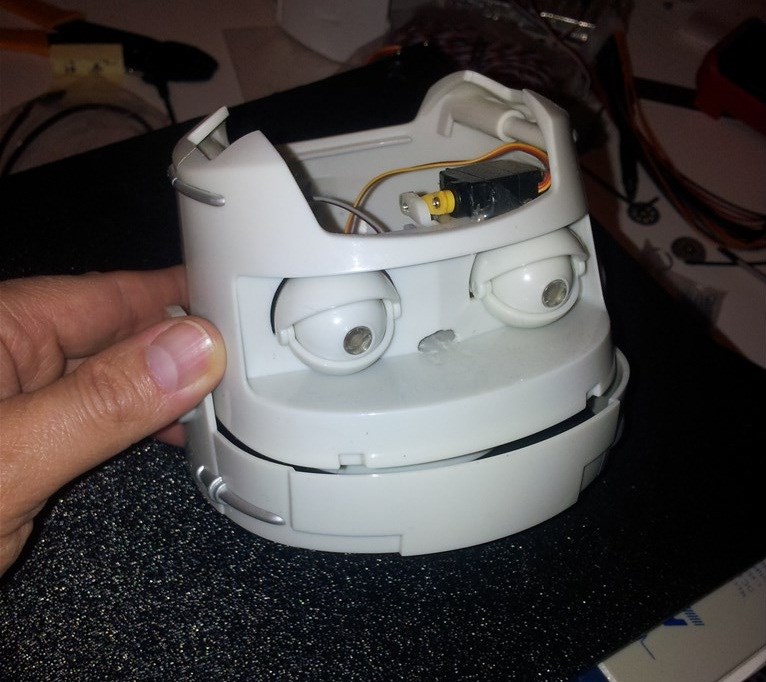


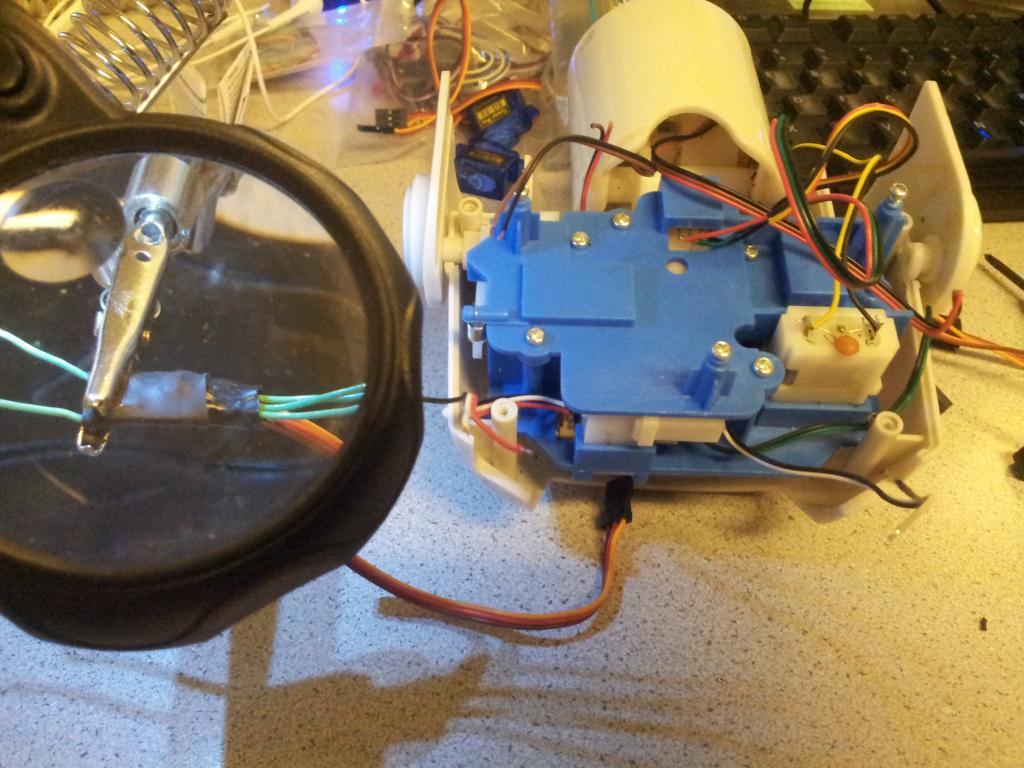
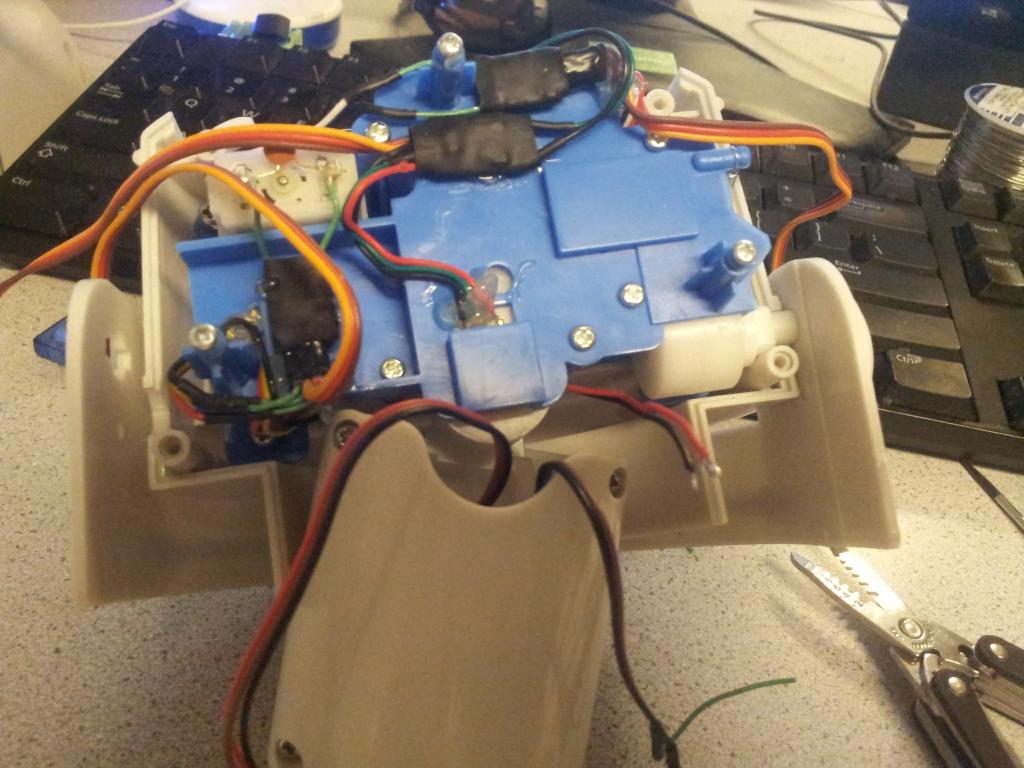

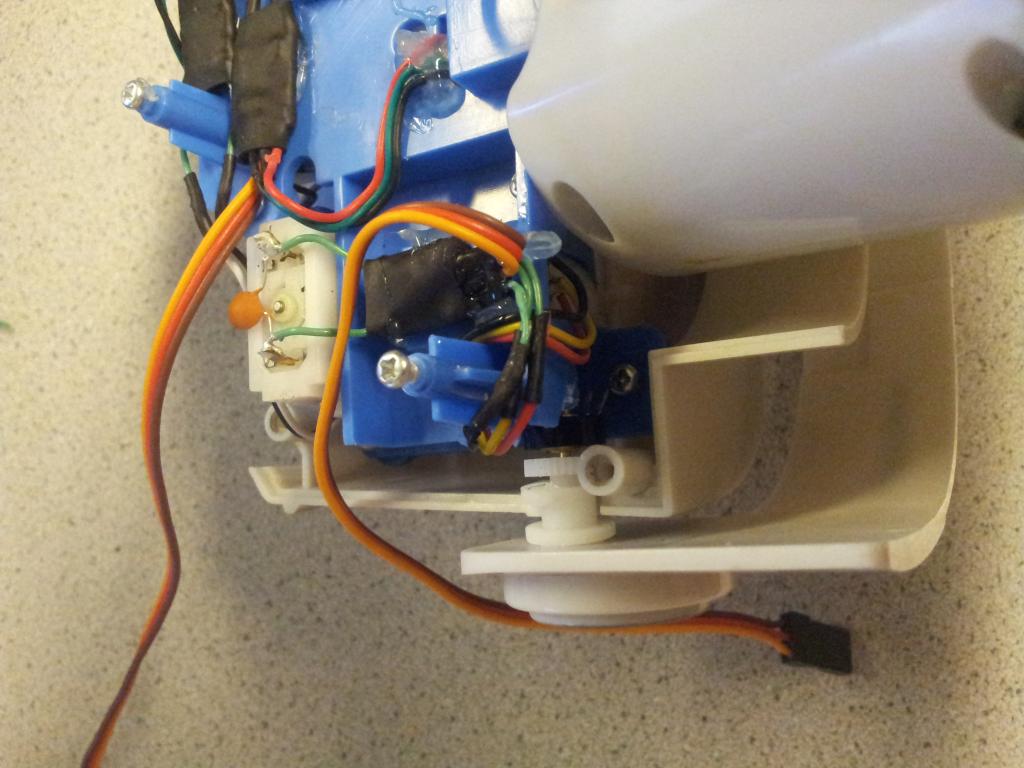

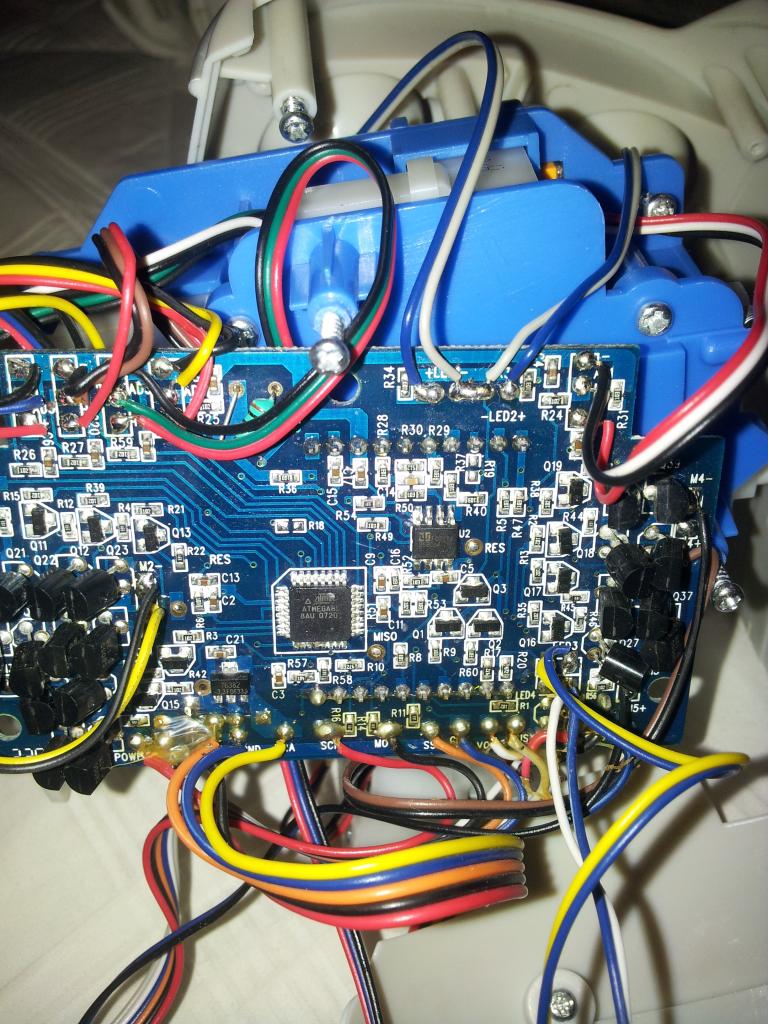
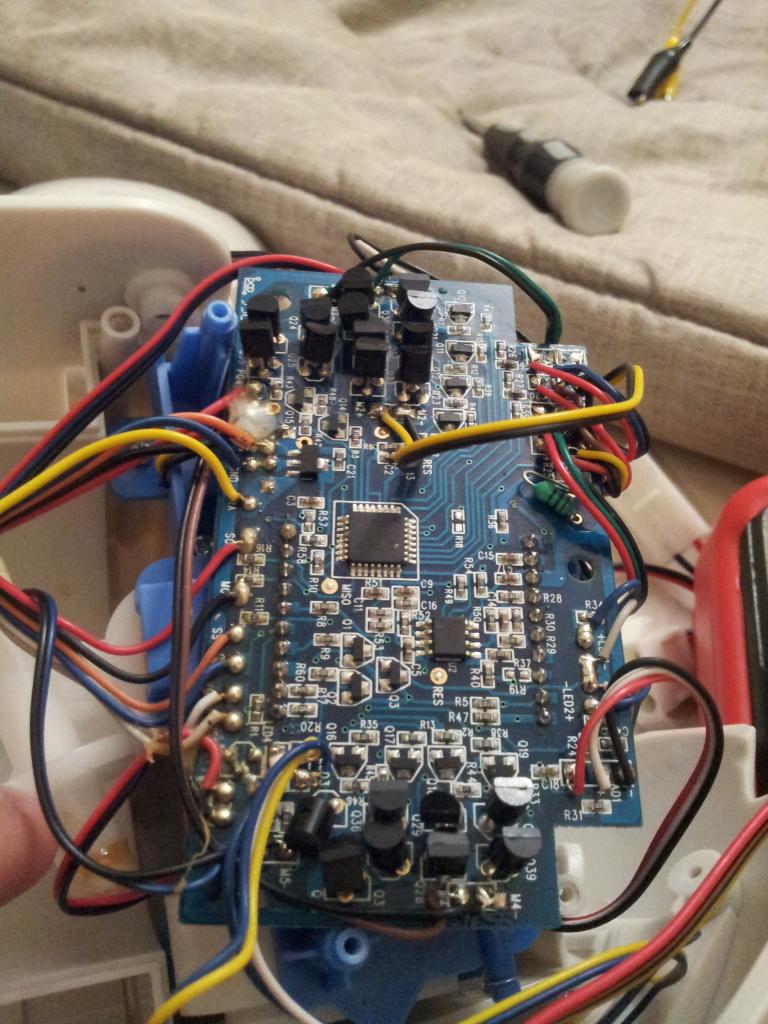
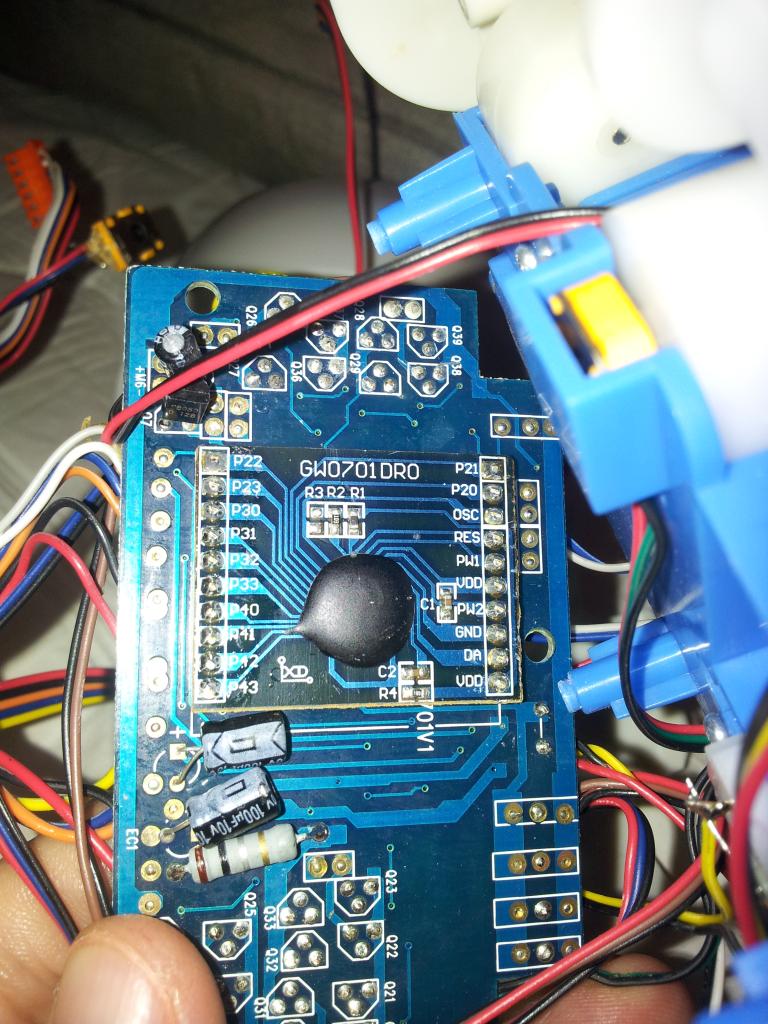


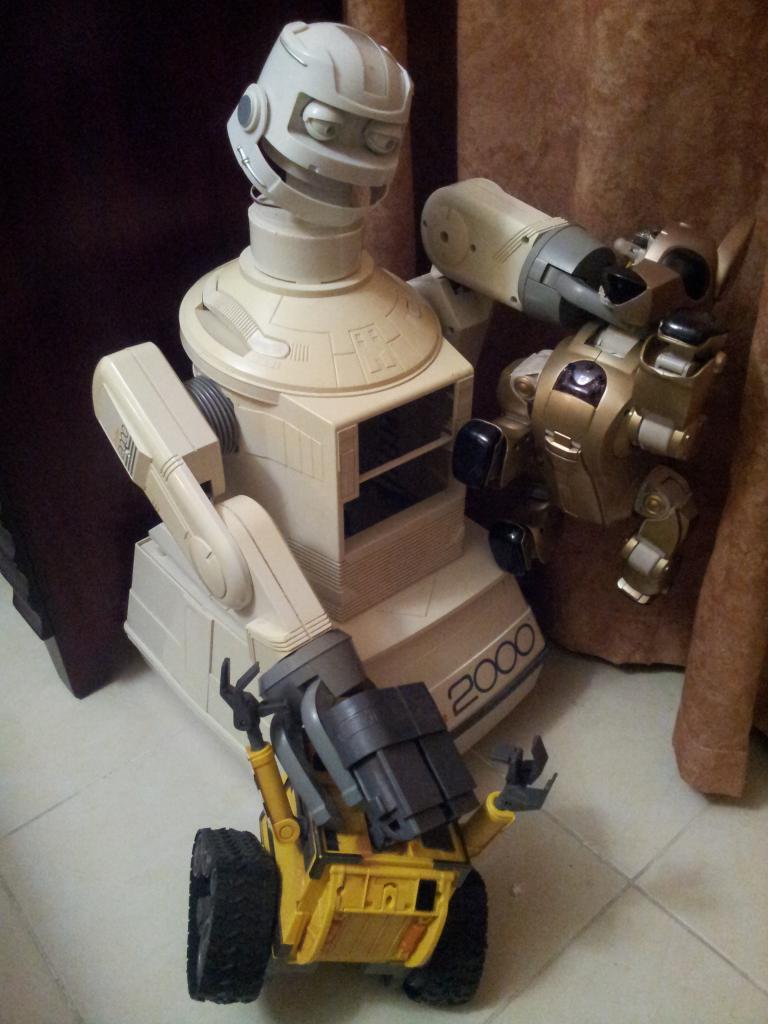
It's just a concept right now but I wanted others to see that the scale doesnt quite match. Right now its just stacked on there and neck is a little too long.
By Troy
— Last update

Discover more robots
Rb550f's Meet Go 2
GO 2 robot with Windows 10 tablet and EZB V4 controller, 30 in tall, tilt head/tablet, waist rotation, quiet 6"...
Louis's Quadrupedal Robot Xr4
Budget quadruped with 1.5mm carbon fiber/aluminum frame, 12 MG995 servos and EZ-B controller for omni-directional...
Cliffordkoperski's F.K.Q. Robot
21 DOF humanoid with 19 servos, 7.4V 2000mAh (1h) runtime, budget brackets/servos, EZ-B v4 and camera for NAO-like...

I am just rolling my eyes! Great job.
sick blush eek J
Thanks guys! I hope more to come soon. No promises. Lol
@Troy no pressure! Lol
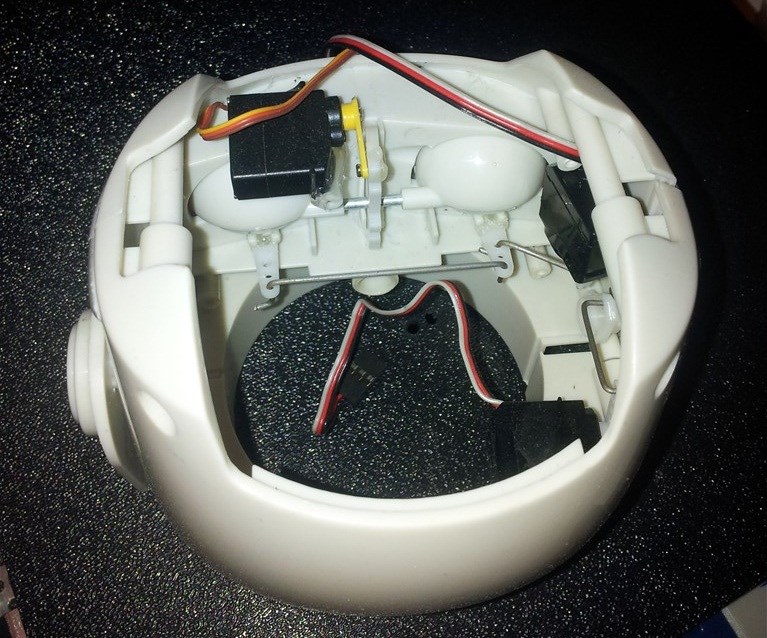
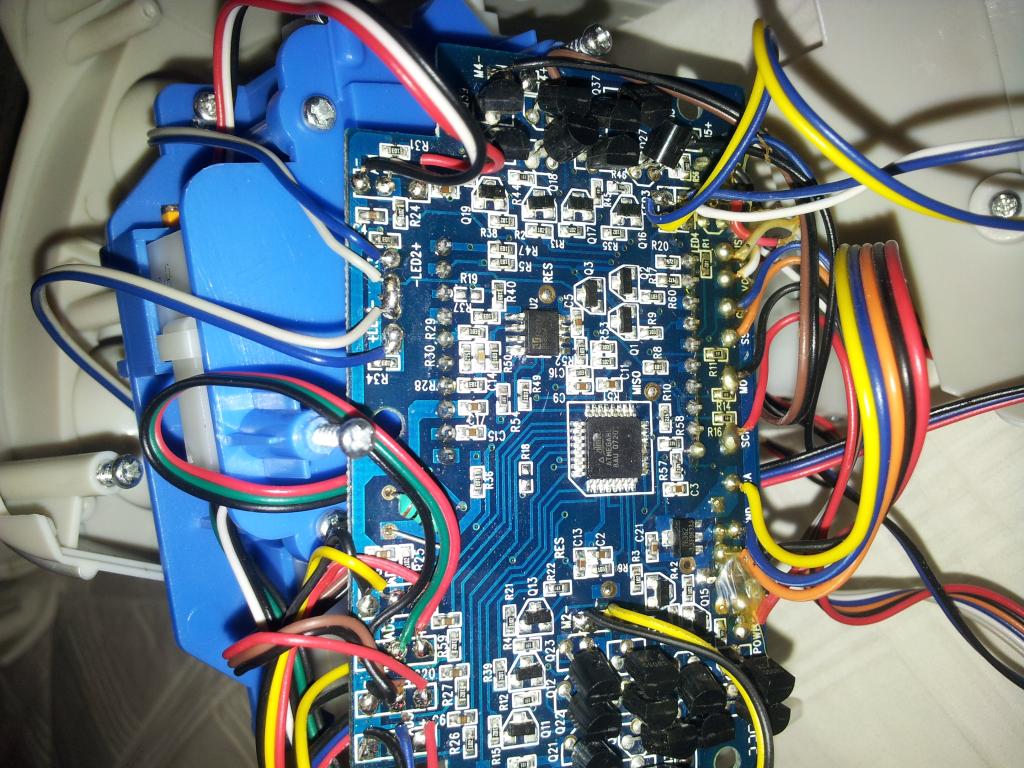
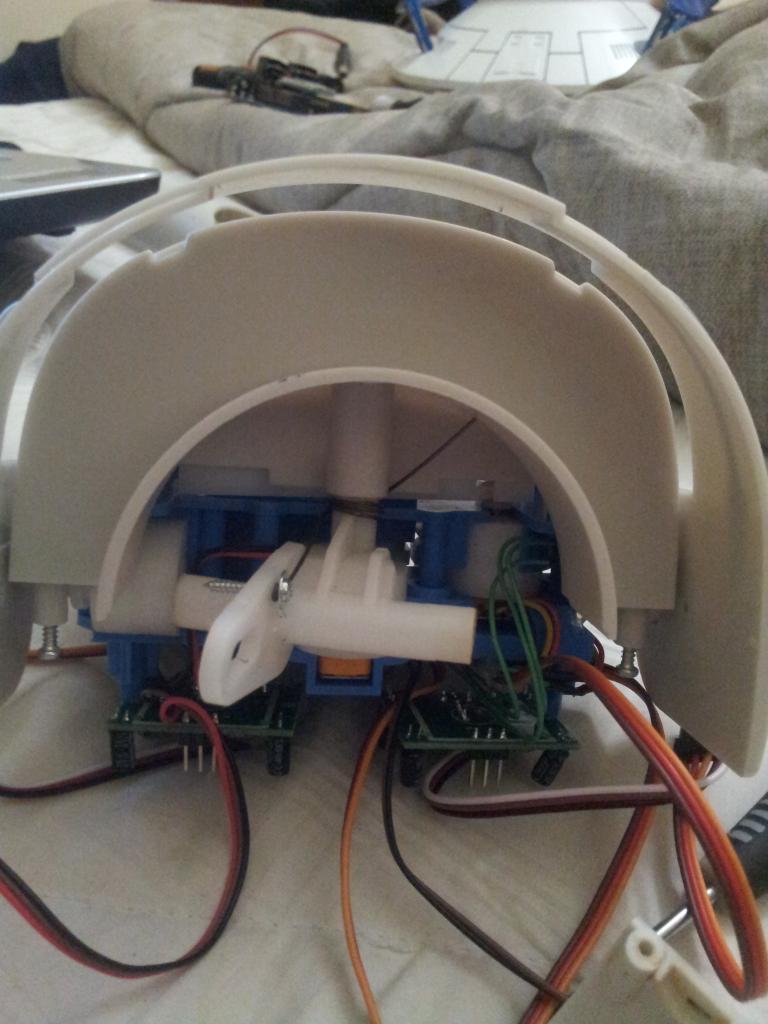
Hi Troy.. would you help me with some more specific "how to" use the head ? I saw in the early posts that you was able to use the native hardware.. how did you do that ? and saw later that you took off all the pieces and put some microservos.. Was that a better solution ?
thanks for all your help!
@tevans, Yes it was better in the long run. There was too much looseness in the neck gears. You can see that in an earlier video. I tried tightening it up with some springs but really it was better for me to replace it. It is also less work than making those servo boards. Also, I freed up more space inside for other things if I decide to use it later. Good luck to you!
LOOKIN' GOOD MY FRIEND!
Hey Troy,
Wow, it took me a little while to catch up. I am so glad to see that you are still working on pinhead. :o)
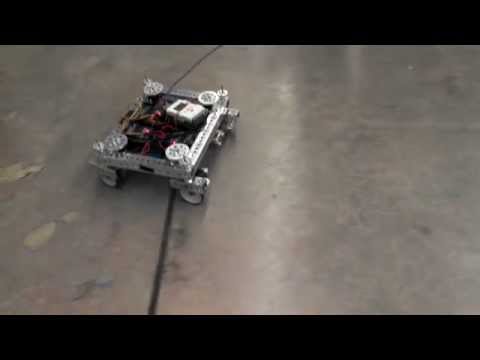
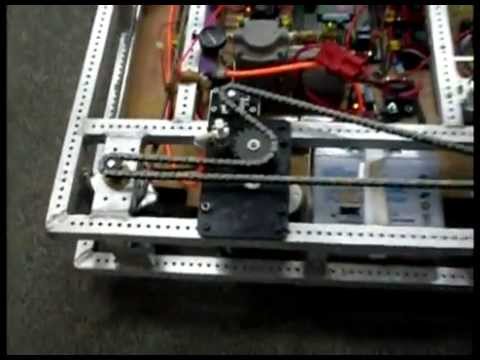
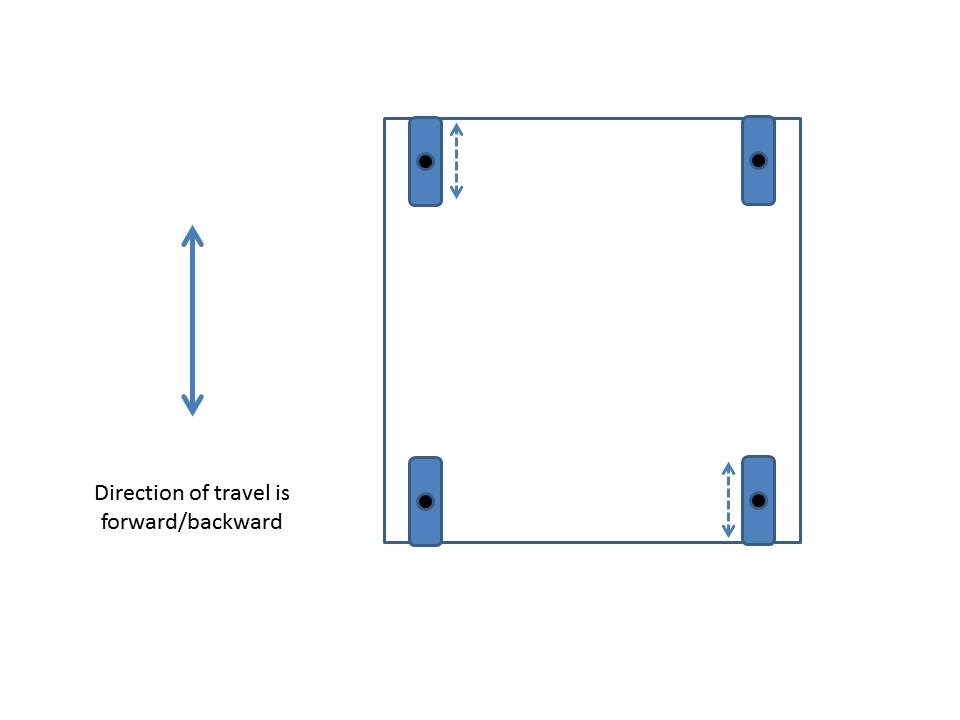
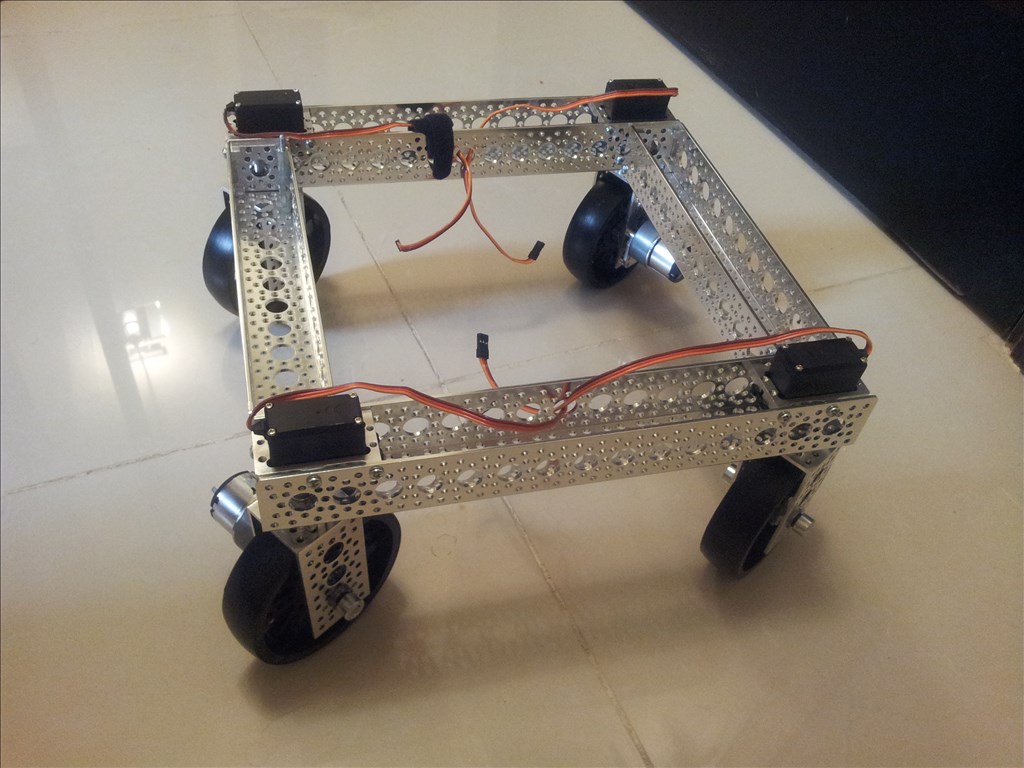
That base looks nice and light wright.
How are things?
heh Pinhead has been on hold again. I still think of new things though.