The Synthiam Robot Skill Store is where you discover new robot skills for ARC and ARCx robot programming software. Install ready-made skills for AI, vision, navigation, speech recognition, servos, and more to quickly expand what your robot can do — whether it's a DIY project or an education robot for the classroom in ARC, or an enterprise product or industrial system in ARCx.
You can also publish your own robot skills for the community or learn how to add existing skills to your robot projects.
 Create a Robot Skill
 What is a Robot Skill?
Most Recent
Most Popular
Adc
Artificial Intelligence
Audio
Camera
Communication
Digital
Display
Games
General
Gps
Graphs
I2c
Infrared Distance
Misc
Movement Panels
Navigation
Power
Pwm
Rafiki
Remote Control
Scripting
Servo
Ultrasonic
Virtual Reality
The Servo category in Synthiam ARC focuses on controlling servo motors, allowing precise control over the rotational movement of robotic components. This skill set is essential for tasks requiring accurate and controlled motion in robotic applications.
For ARC
Auto Position (Gait)
Create servo frames and actions to animate gaits and gestures with automatic motion planning, software ramping, movement panel, import/export
For ARC
Auto Release
Auto-release servos after inactivity: set EZB board/ports, choose 1-60s delay, add/remove ports, pause and view status.
For ARC
Continuous Servo

Control a 3-wire continuous 360-degree servo in ARC: adjustable forward/reverse speeds, start/stop buttons, board/port selection and test controls
For ARC
Custom Servo Controller v3
Control up to 99 servos over serial with Vx virtual ports using custom firmware on Arduino or microcontroller controllers.
For ARC
Dynamixel v53
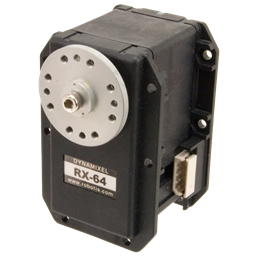
Open-source ARC plugin to control Robotis Dynamixel servos (XL-320, AX-12, XL430) via EZ-B, Arduino or Robotis. Supports position, speed, accel.
For ARC
Feetech RS485 Servo v10
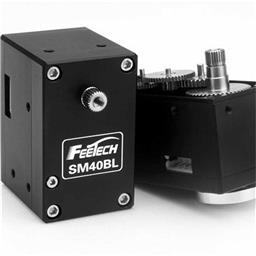
Control Feetech serial bus smart servos via EZB UART or PC COM port in ARC using virtual ports mapped to servo IDs.
For ARC
Feetech Serial Bus Servo v15
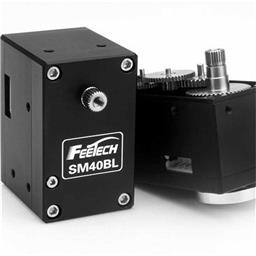
Control Feetech SC serial bus smart servos via EZB UART or PC COM port with ARC virtual ports, speed, position, release, and acceleration.
For ARC
Horizontal Servo
Mouse-drag horizontal servo control with configurable min/max limits, center/release functions, multi-servo mirroring and direction invert.
For ARC
Inverse Kinematic Arm v12
Control robot arms with inverse and forward kinematics, converting X/Y/Z positions into joint motion and reporting end-effector location.
For ARC
Kondo KRS ICS Servos v7
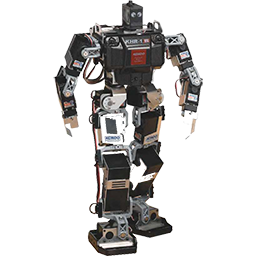
Control Kondo KRS ICS2/3.5 servos via EZ-B UART; experimental, untested. Supports chaining, virtual servo ports, Release() and Servo() commands.
For ARC
Lewansoul Servo v30
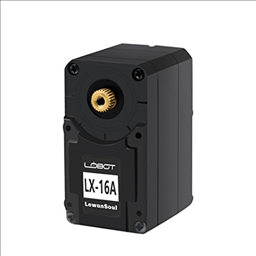
Control LewanSoul LX-16A servos via ARC (EZ-B v4/IoTiny): assign virtual ports, read positions, set speeds, and enable continuous rotation.
For ARC
Lynxmotion Smart Servos v9
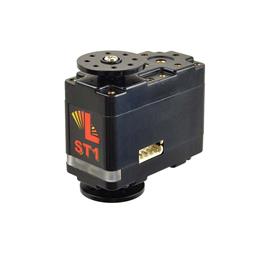
Compact Lynxmotion Smart Servos with position feedback, safety features and UART TX/RX for Arduino/EZ-B v4; scriptable temp, load, load-dir and ping.