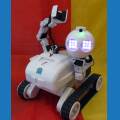
I create here a thread about my Robot. First steps, buildings, Errors and mistakes.
More robots by Stiko
Other projects from the same builder.
Discover more robots
Robots the community built with Synthiam ARC. Get ideas for your next build.
Kullthulu's Artemis - The Household Service Bot
Artemis robot: Max '99 platform with EZBV4, pan/tilt servos, 3Dprinted arms, camera for object tracking/face...
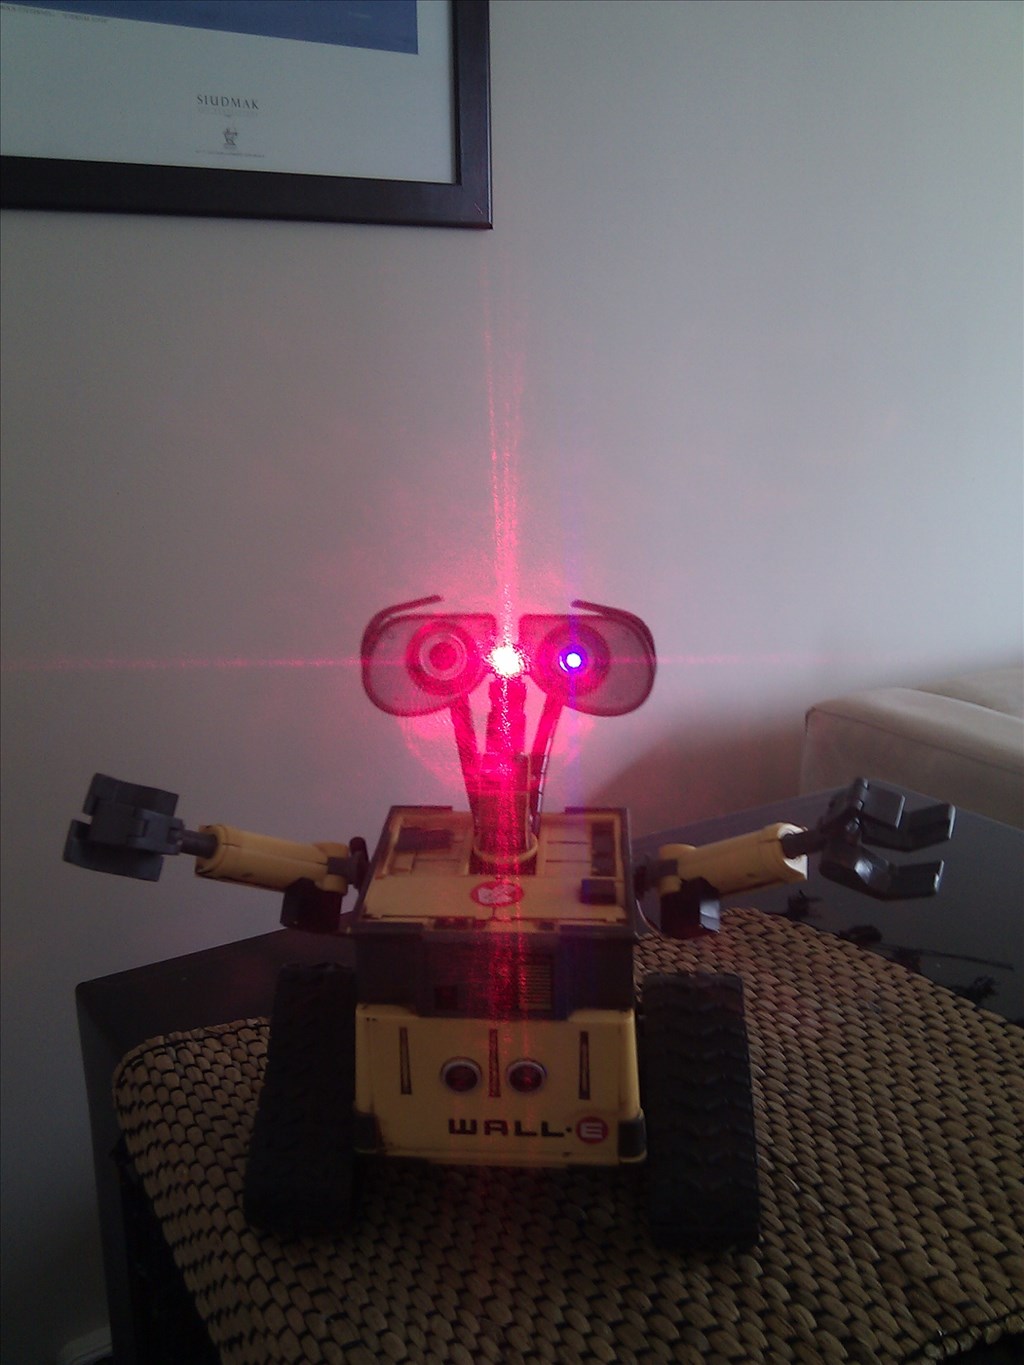
Fisha's Wall-E Wall-E From Poland - Tribute To My Newborn...
DIY Wall-E robot with 12-14 servos, camera, ultrasonic sensor, MP3 trigger, amplifier, laser diode, VU meter mouth and...
Justinratliff's Jd Spock
JD Spock 3D-printed Star Trek TOS phaser sized for JD, color-matched EZ_OST_phaser.stl and printable paper headpiece...

I started searching for a driving camera. The best thing I wanted was a robot with which I could grab things. JD was perfect for me. I experimented with JD but he runs very slowly. I tried to lengthen the legs. There were problems with the stability. I bought him wheels.
With the wheels he could not drive small steps. Now I got Rolli and built a centaur.
After 30-40 minutes the battery was always empty. I needed a big battery. Now the robot can be used for 6-8 hours with only one battery.
Controlling two arms is not easy. Except for the optics, I found 2 arms senseless. I put the robot on a movable arm. The stress on the rotation servo is too great. The stability is not given.
I tested 2 weeks all positions for one arm. I also wanted to be able to store objects in the body. Then I had the perfect idea. Through the integration of a vehicle and working mode, I was able to fulfill all wishes.
The chains have always slipped. Either they were too tight. Or these were too loose. For normal operation these were ok. As soon as the robot turned, the chains slipped.
Now I attached to each drive wheel a self-sealing tape. Now the chains work perfectly again.
Now i have make a first operating Video with the new Version from my robot EZRI.
Here you can see the robot with full operating arm and grabber.
Nice work! well thought out and great trouble shooting technique.