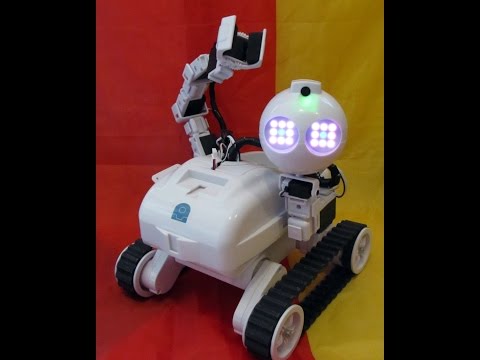
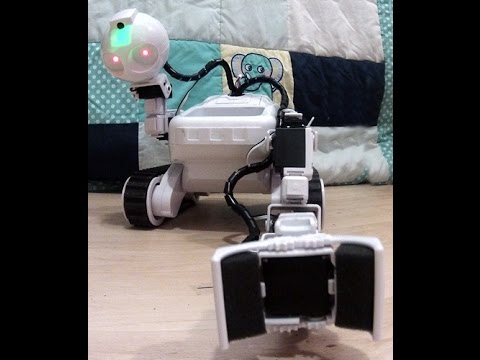
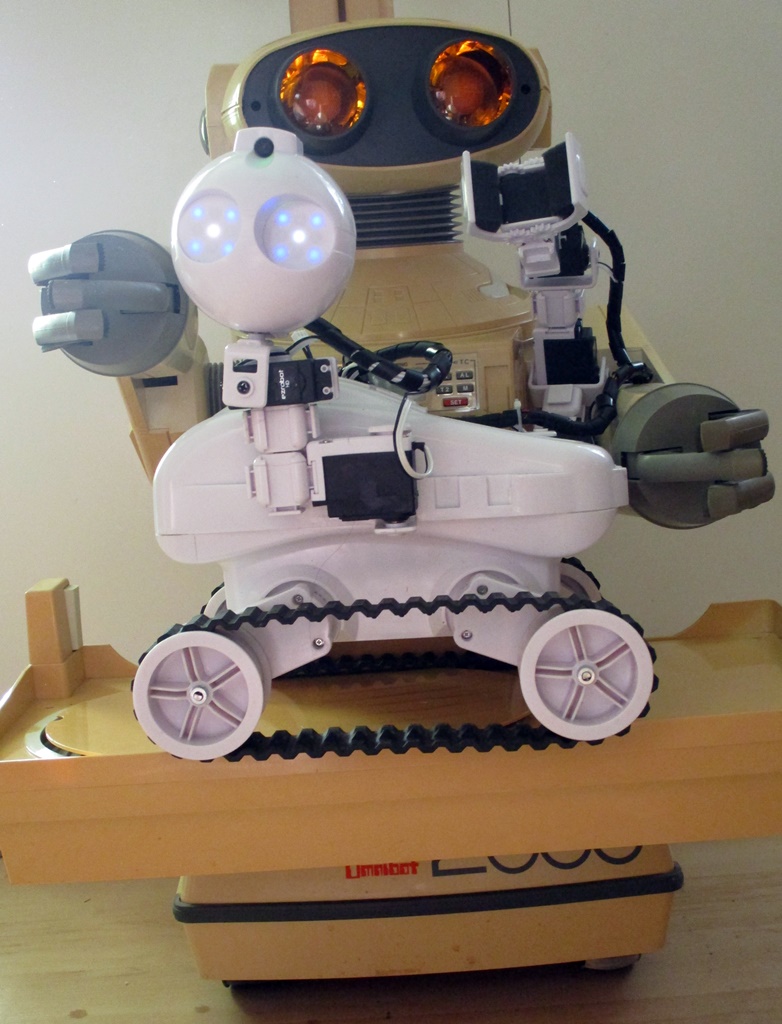
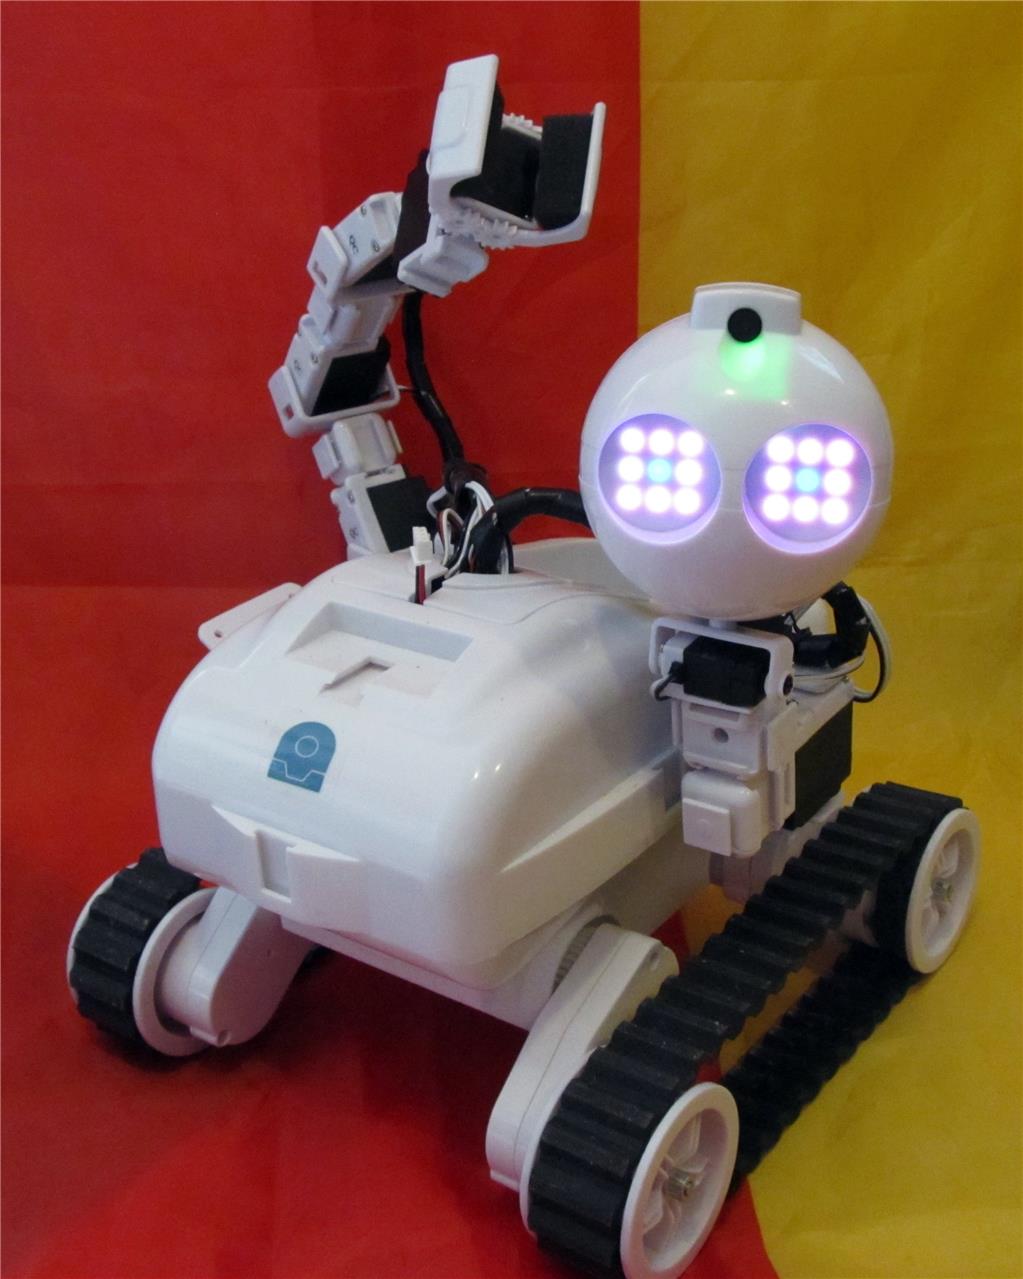

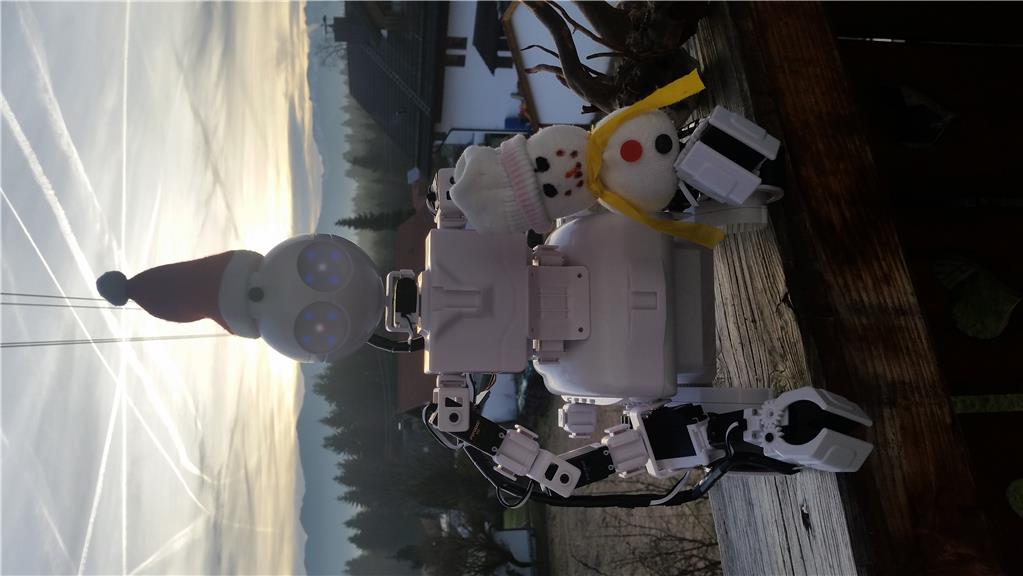
I create here a thread about my Robot. First steps, buildings, Errors and mistakes.
By Stiko
— Last update
Discover more robots
Animator28's AVA (Advanced Visual Android) Update
3D-printed robot head using micro DC motors with H-bridges and EZB, screen face with projector-driven animations, TTS...
Keithjmoore's My First Robot
iRis telepresence robot: a first DIY build in progress to serve as a telepresence platform for work.
Dave's Hello All
Control Johnny 5 replica with EZ-B controller - easy starting point for testing and learning robot control and...

I started searching for a driving camera. The best thing I wanted was a robot with which I could grab things. JD was perfect for me. I experimented with JD but he runs very slowly. I tried to lengthen the legs. There were problems with the stability. I bought him wheels.
With the wheels he could not drive small steps. Now I got Rolli and built a centaur.
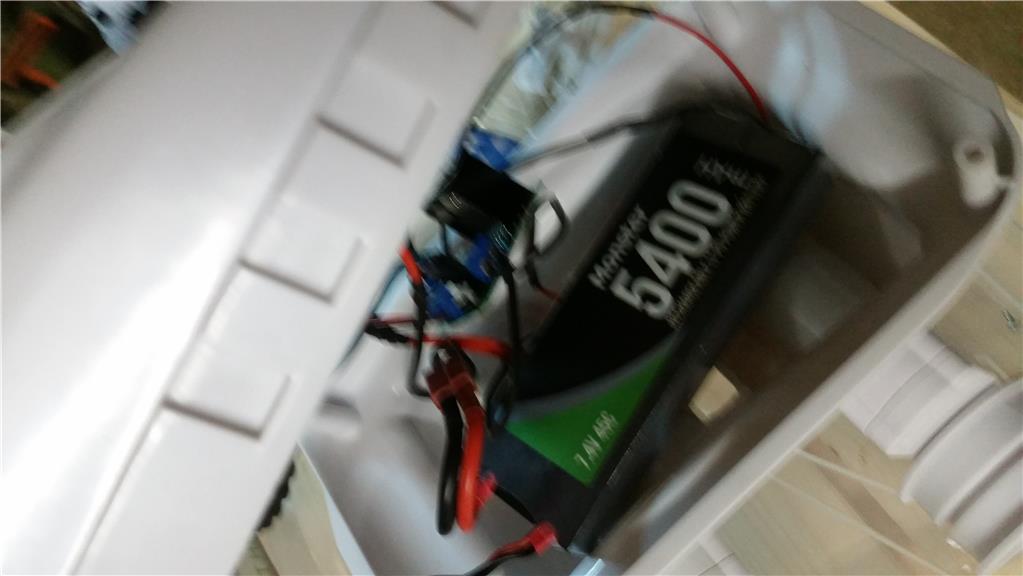
After 30-40 minutes the battery was always empty. I needed a big battery. Now the robot can be used for 6-8 hours with only one battery.
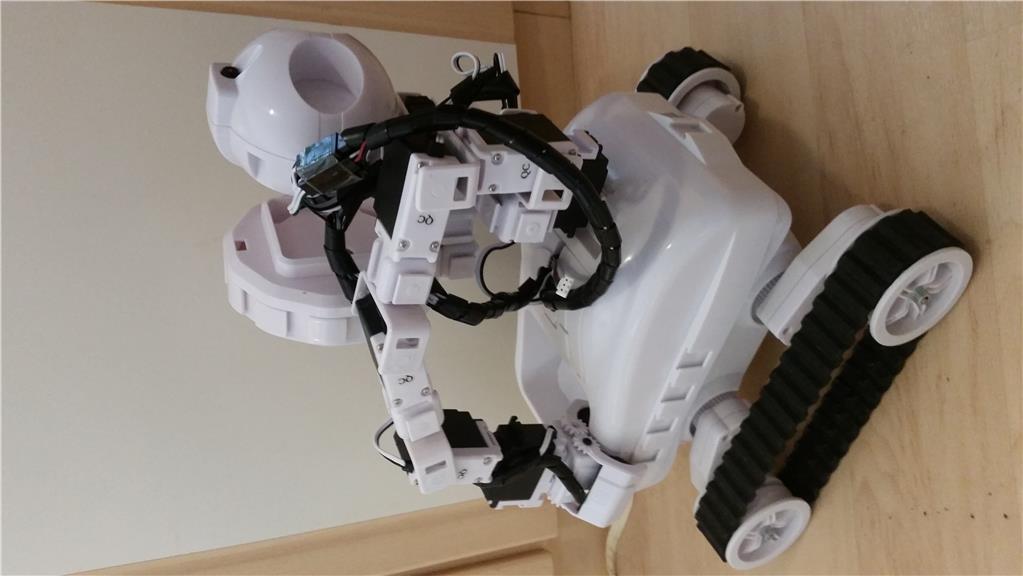
Controlling two arms is not easy. Except for the optics, I found 2 arms senseless. I put the robot on a movable arm. The stress on the rotation servo is too great. The stability is not given.
I tested 2 weeks all positions for one arm. I also wanted to be able to store objects in the body. Then I had the perfect idea. Through the integration of a vehicle and working mode, I was able to fulfill all wishes.
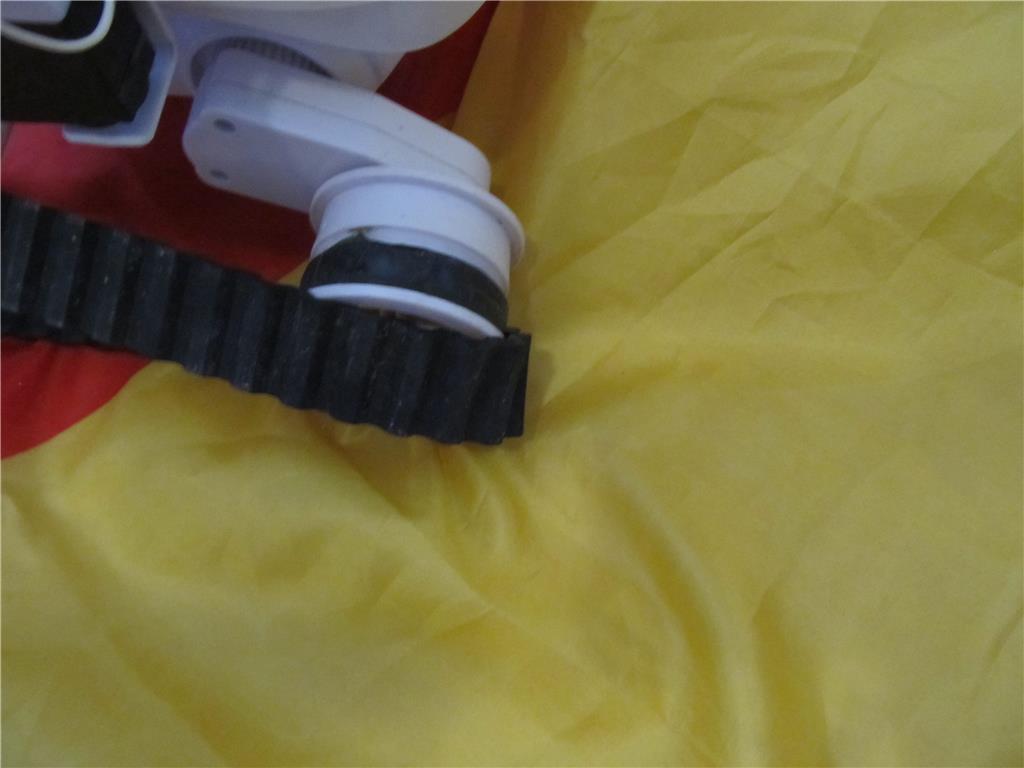
The chains have always slipped. Either they were too tight. Or these were too loose. For normal operation these were ok. As soon as the robot turned, the chains slipped.
Now I attached to each drive wheel a self-sealing tape. Now the chains work perfectly again.
Now i have make a first operating Video with the new Version from my robot EZRI.
Here you can see the robot with full operating arm and grabber.
Nice work! well thought out and great trouble shooting technique.