
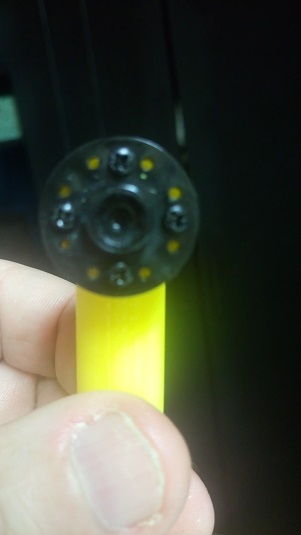
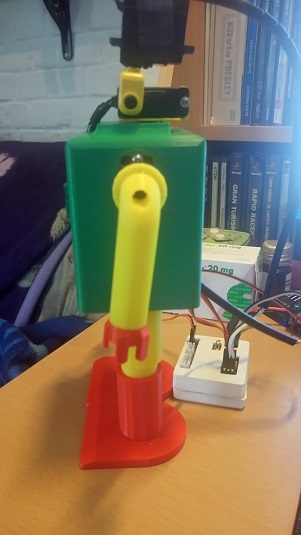
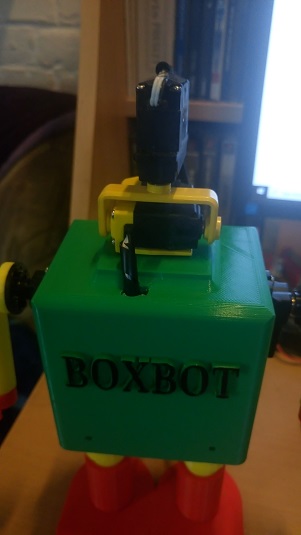
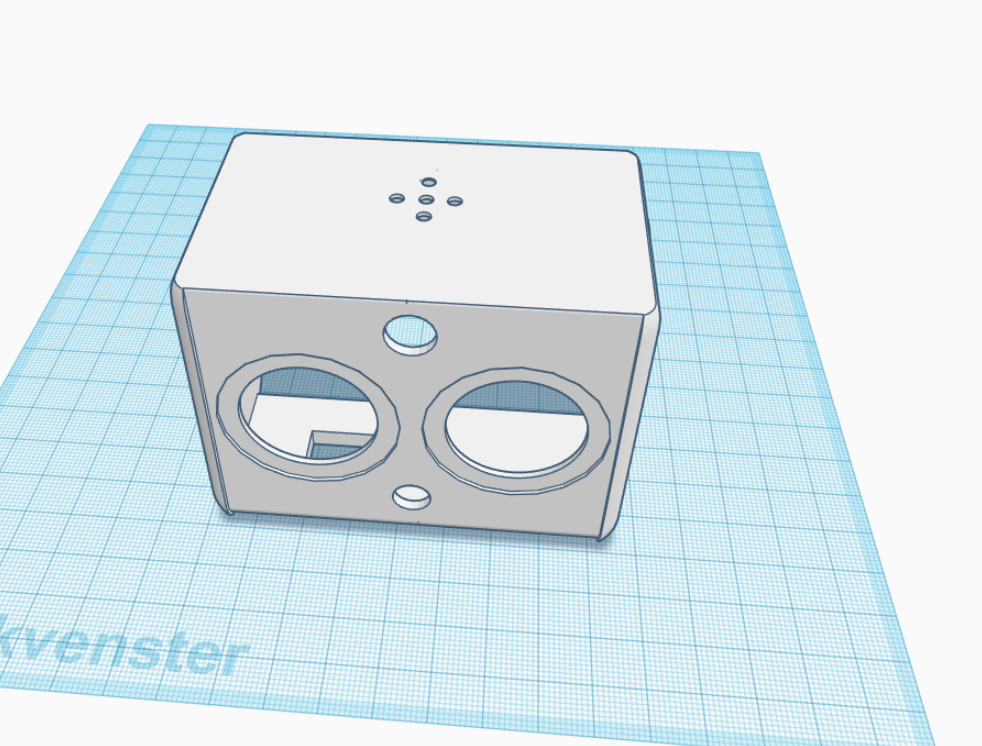

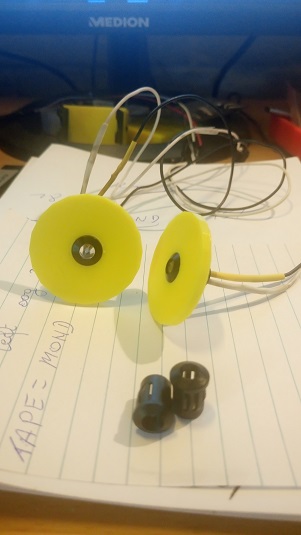
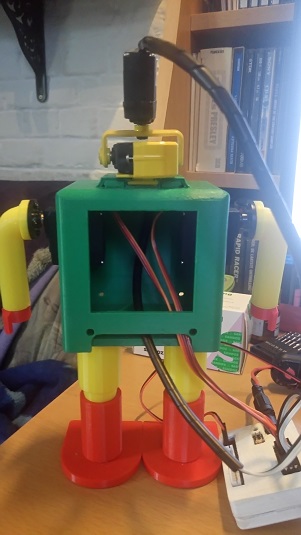
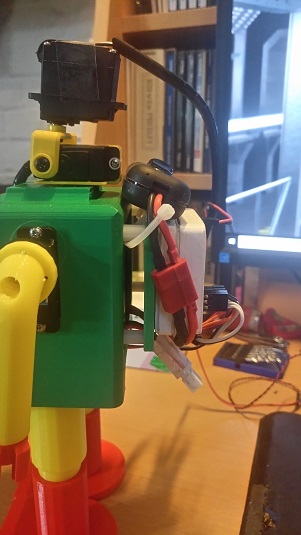
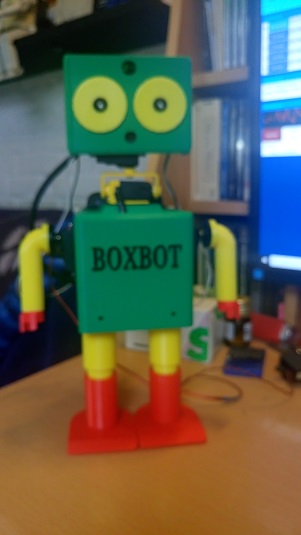
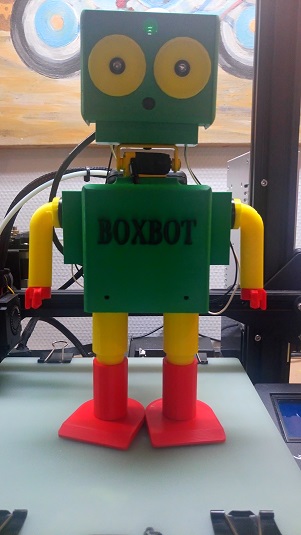
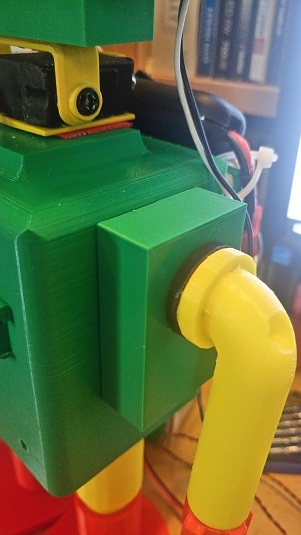
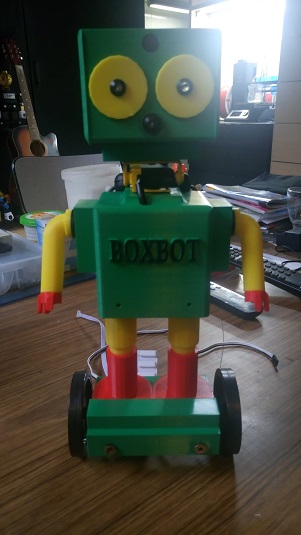
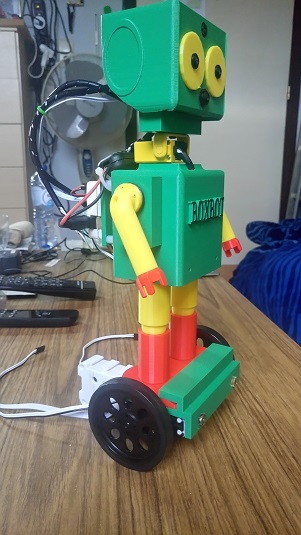
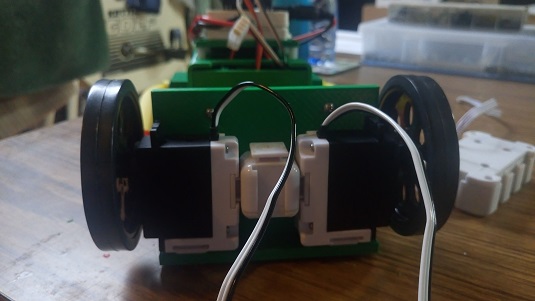
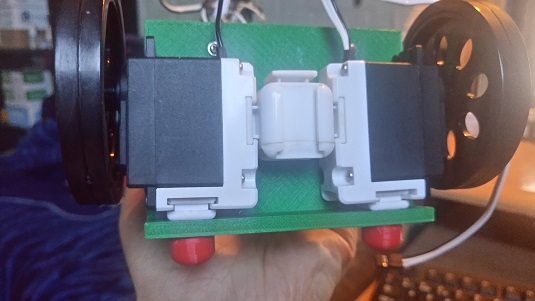
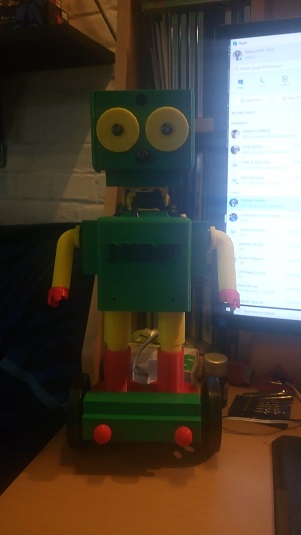
P2 stands for printed second version boxbot.cause dj made the first boxbot. the V1 stands for version 1.version V2 will get some wheels. this robot is a desk robot to train excample camera /position movements and more. it has 4 micro servo's camera still to come ,two flat eye LED blue. the red covers lowerlegs are changeble i, other colors. still need to do .head to print/camera /choulder covers (servo's )
By Nomad 6R
— Last update

Discover more robots
Fxrtst's Project Gargantua (Or Gar)
Hexapod centaur robot with arm cannon, 53 PETG 3D-printed parts, 23 servos, 7600mAh LiPo, EZ-Robot servos, EZB, onboard...
DJ's Irobot Roomba Hack
Convert an iRobot Roomba with EZ-B to a wireless, voice- and vision-enabled cleaner-camera color/motion tracking, remote...
Cyberdude's Cyberdude's Wall-E
Convert robot head to nod with micro metal-gear servos, hidden wiring, compact camera and ping-sensor mounts, and...

hey ezang
i am still using PLA.
ok thanks
EzAng
Did you ever use PETG?
no only PLA.no other filaments.
some adjustment are made on the head. there is room for the camera and a little speaker.
I am here, a little slow out here :-)
looks great, my robot friend -
any videos?
EzAng
i have to upload a video.
i am uploading the video now.