
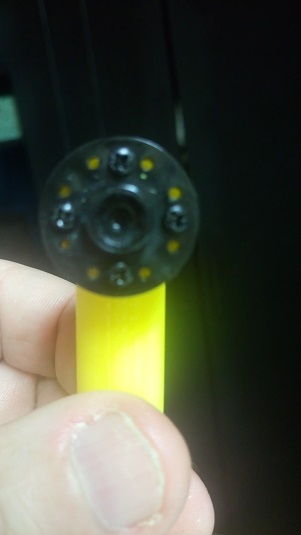
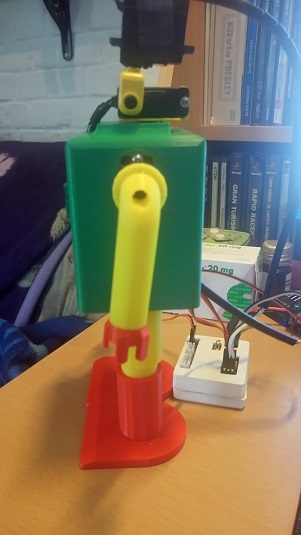
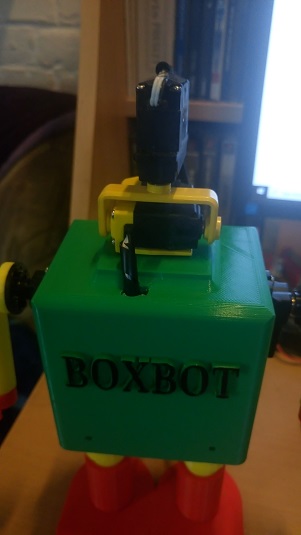
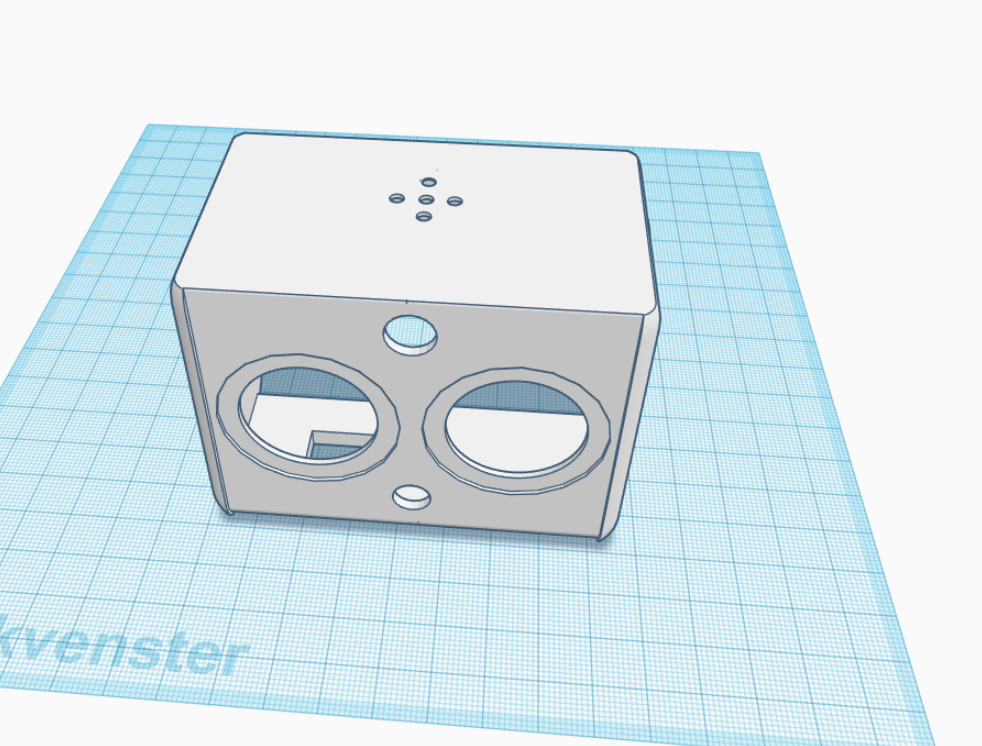

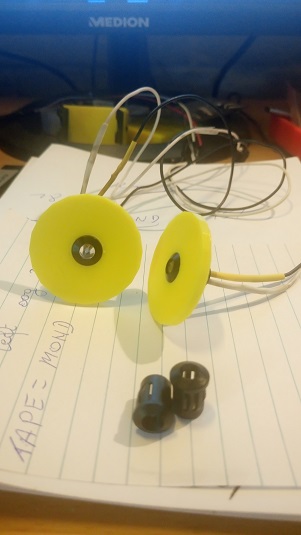
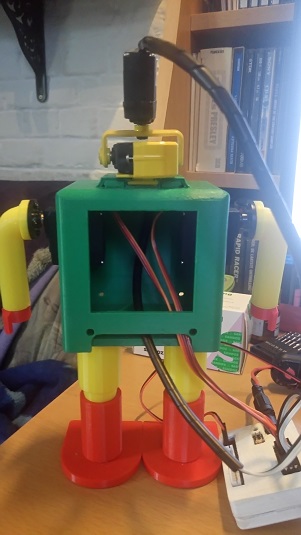
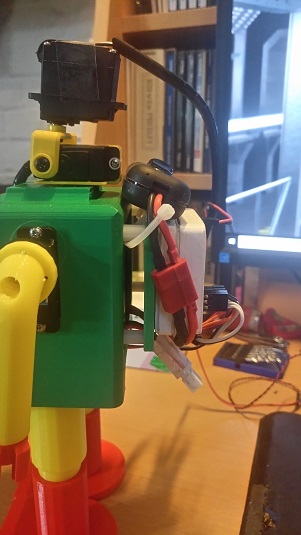
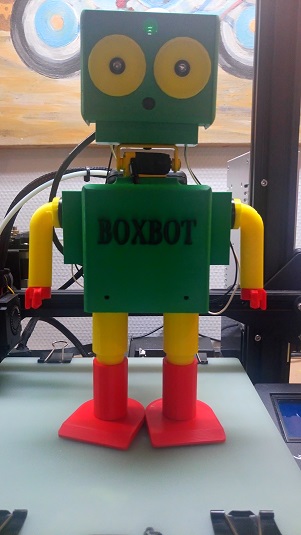
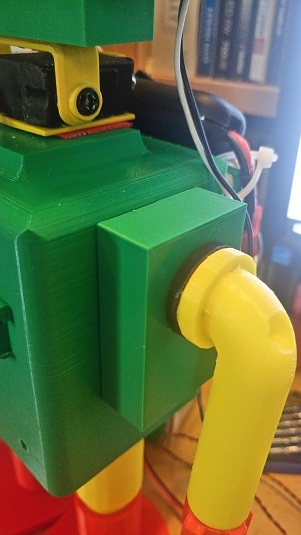
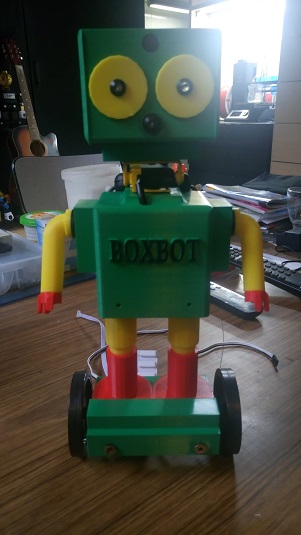
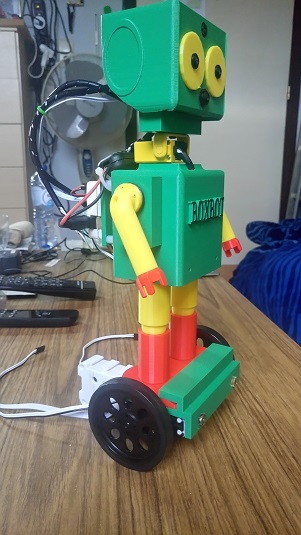
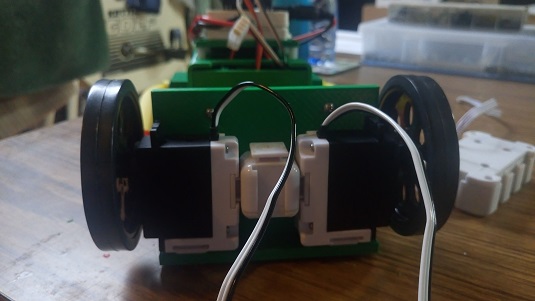
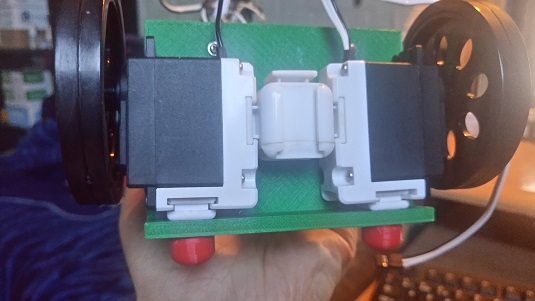
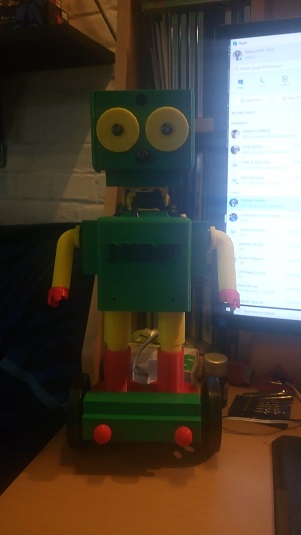
P2 stands for printed second version boxbot.cause dj made the first boxbot. the V1 stands for version 1.version V2 will get some wheels. this robot is a desk robot to train excample camera /position movements and more. it has 4 micro servo's camera still to come ,two flat eye LED blue. the red covers lowerlegs are changeble i, other colors. still need to do .head to print/camera /choulder covers (servo's )
By Nomad 6R
— Last update

Discover more robots
Haydenbot's Hayden's First Robot Captain America
Captain America robot built with loTiny EZ Robot controller and continuous servos; EZ Robot ramp-up scripts smooth...
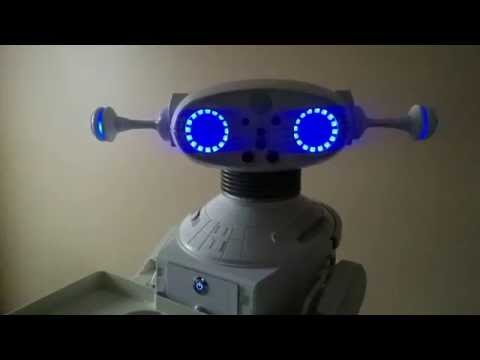
Leversofpower's Omnibot 200 Mod Progress
Control Omnibot EZ-B lighting via Arduino Mega over serial with NeoPixel LED effects, programming progress and...
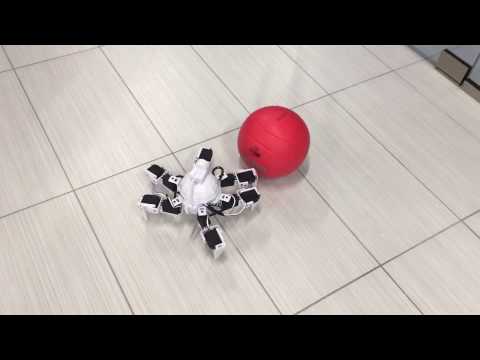
DJ's Six Hexapod Robot Tracking Ball
Synthiam ARC configures a Six Hexapod to track and chase a red ball with tutorials, Robot Program episodes and EZ-Robot...

hey ezang
i am still using PLA.
ok thanks
EzAng
Did you ever use PETG?
no only PLA.no other filaments.
some adjustment are made on the head. there is room for the camera and a little speaker.
I am here, a little slow out here :-)
looks great, my robot friend -
any videos?
EzAng
i have to upload a video.
i am uploading the video now.