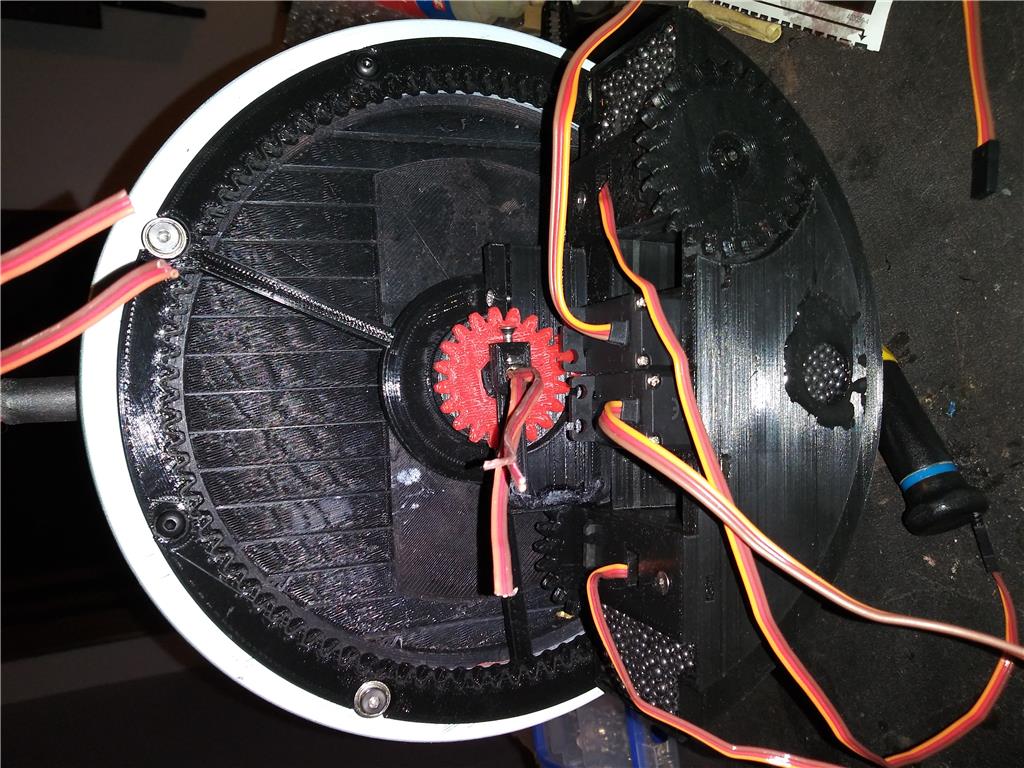
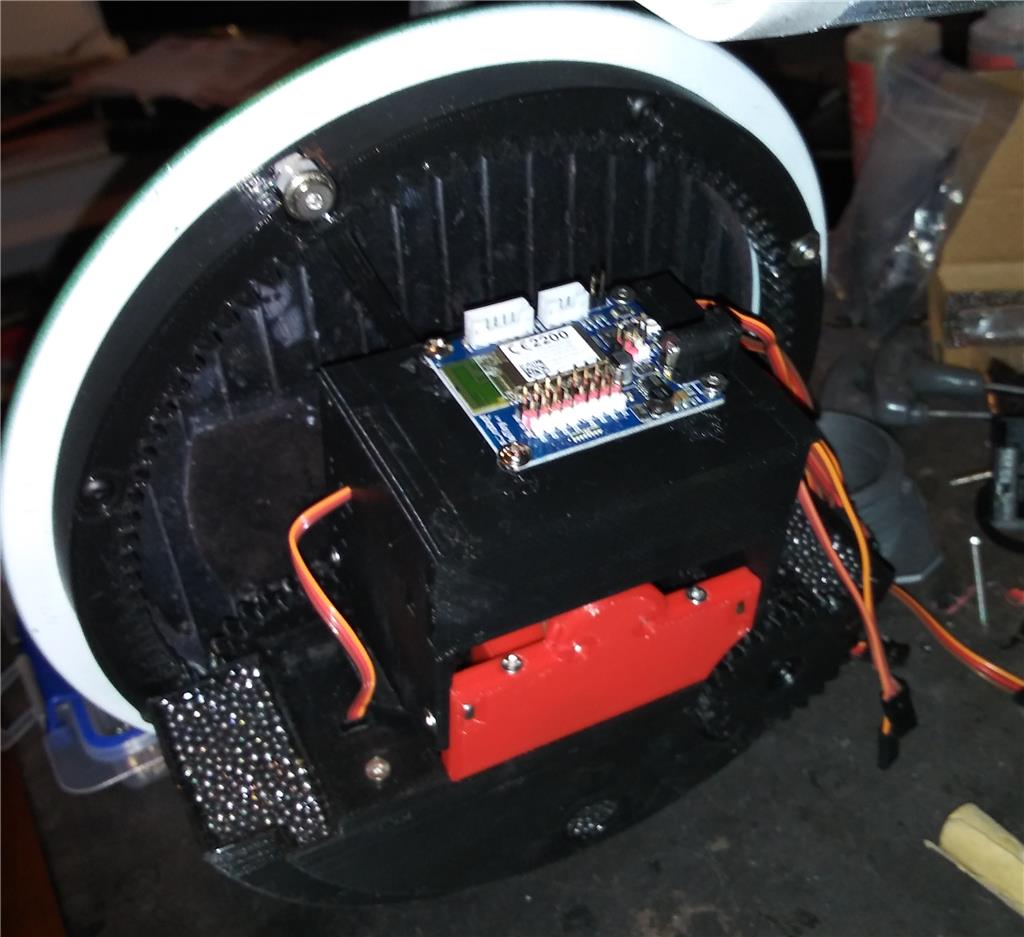
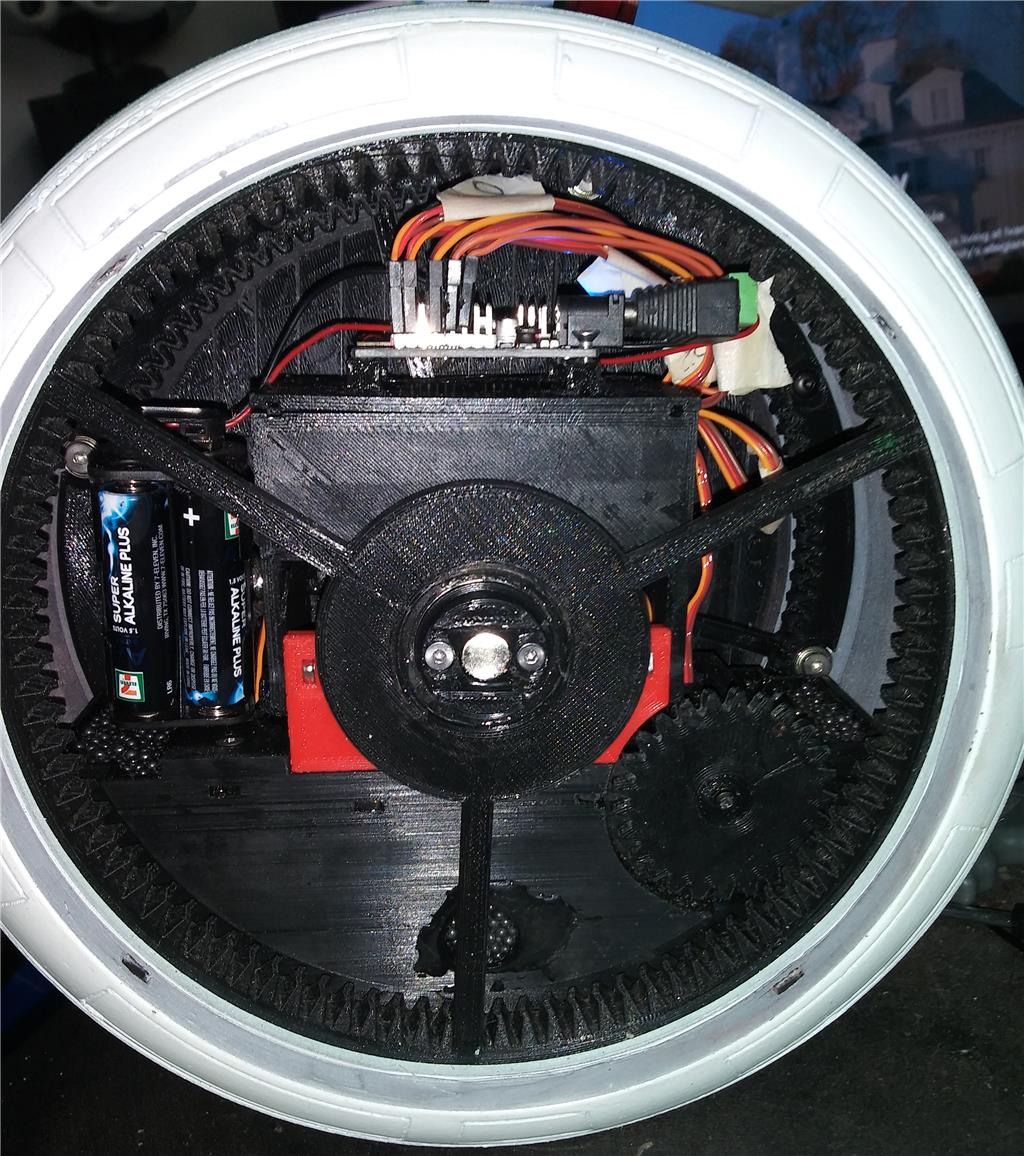
Here is my D-O droid powered by the IoTiny and controlled through my tablet.
The head is too heavy for the servo in the body, it wants to tilt forward so the nose hits the ground. so I had to lock it up. Otherwise it has the function for the bar holding up the head to tilt back and forth.
By kashyyyk
— Last update



Discover more robots
Daman's Meet Ray. My Custom Friendlybot
Custom Ray box-bot with foam board body, tracked drive and ping sensor, explores servo torque limits and DC...
Justinratliff's Jd Backpack
JD backpack mockup anchors into JD's middle slot with male clip, two top posts, dual rear mounts, wire access and switch...
Oakmot's Chloe Project
Home mannequin robot using EZ-B servos, camera face-tracking and Synthiam ARC control with DC power, arm plans, and...

Wow! That's a 3D printing masterpiece!
That is so flip'n cool!
WoW is Right. What are you using for the counter weight. I think it looks like shot. Maybe you just need more counterweight to compensate for the Head weight. if you do not have enough room try making a solid lead weight. Have you thought of a GYRO. for balance. Thanks for showing the insides.
It has about 4 pounds of shot. The head rod is connected to a servo to tilt it back and forth, the red gear in the first image, the counter weight doesn't affect the head, only keeps the whole assemble from spinning.