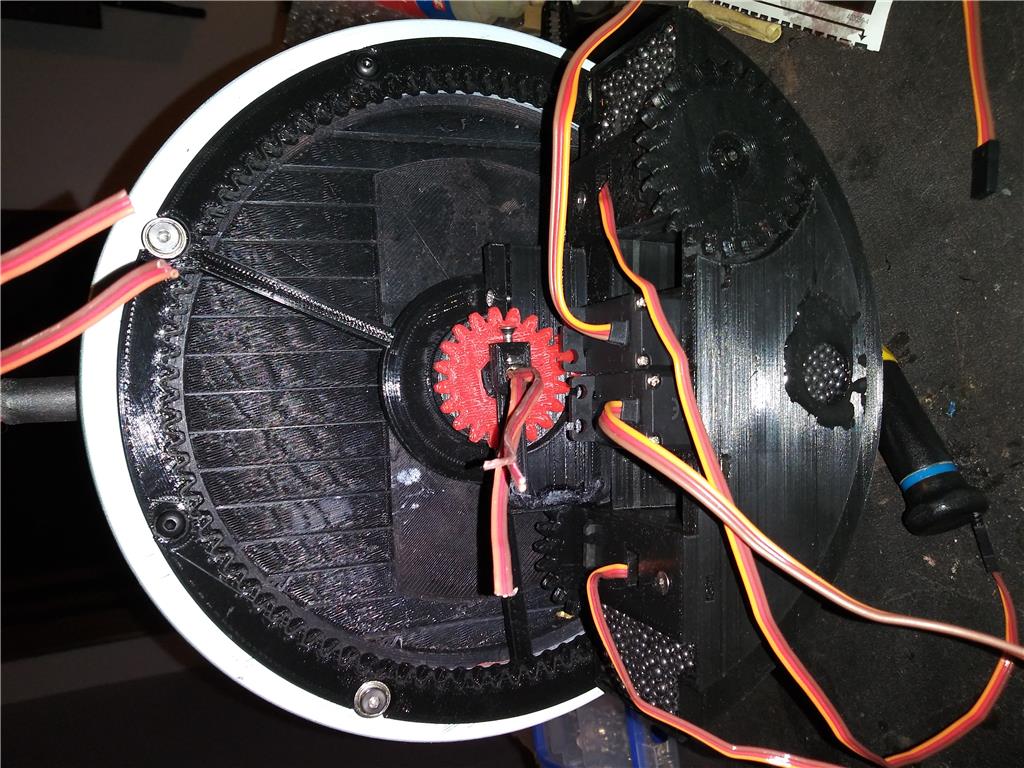
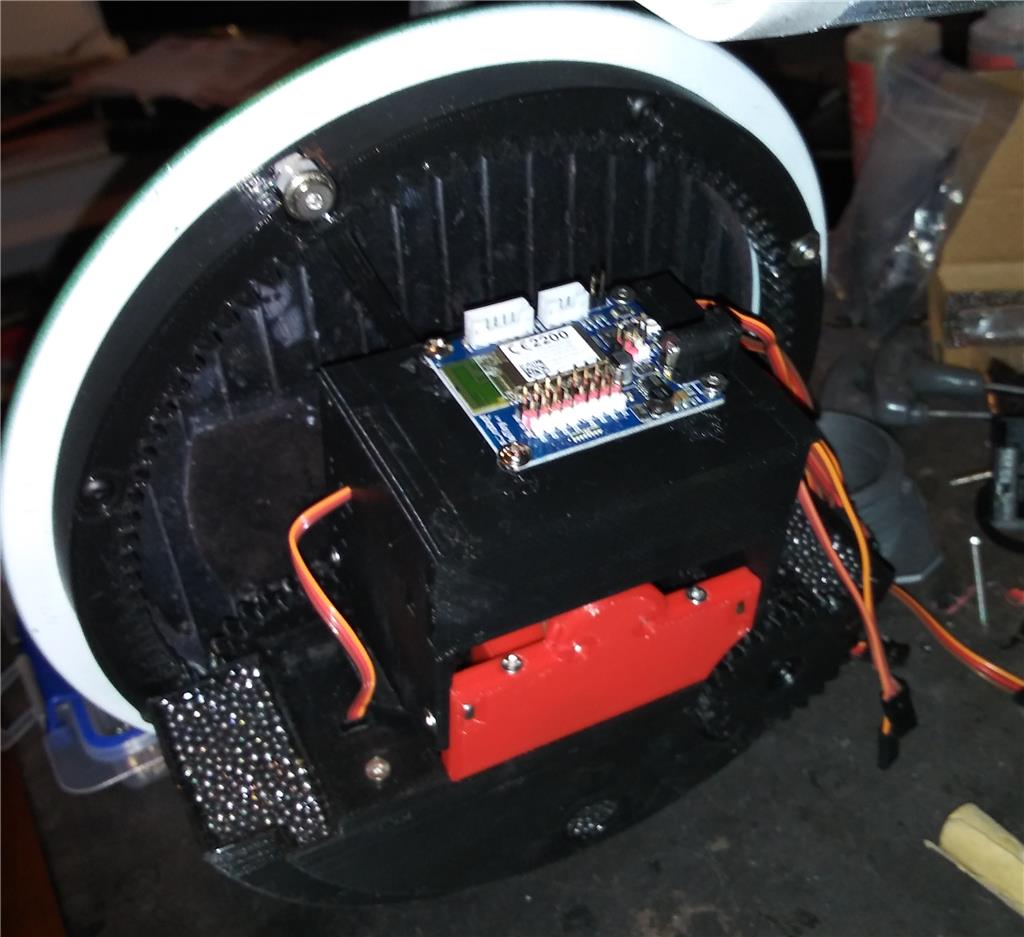
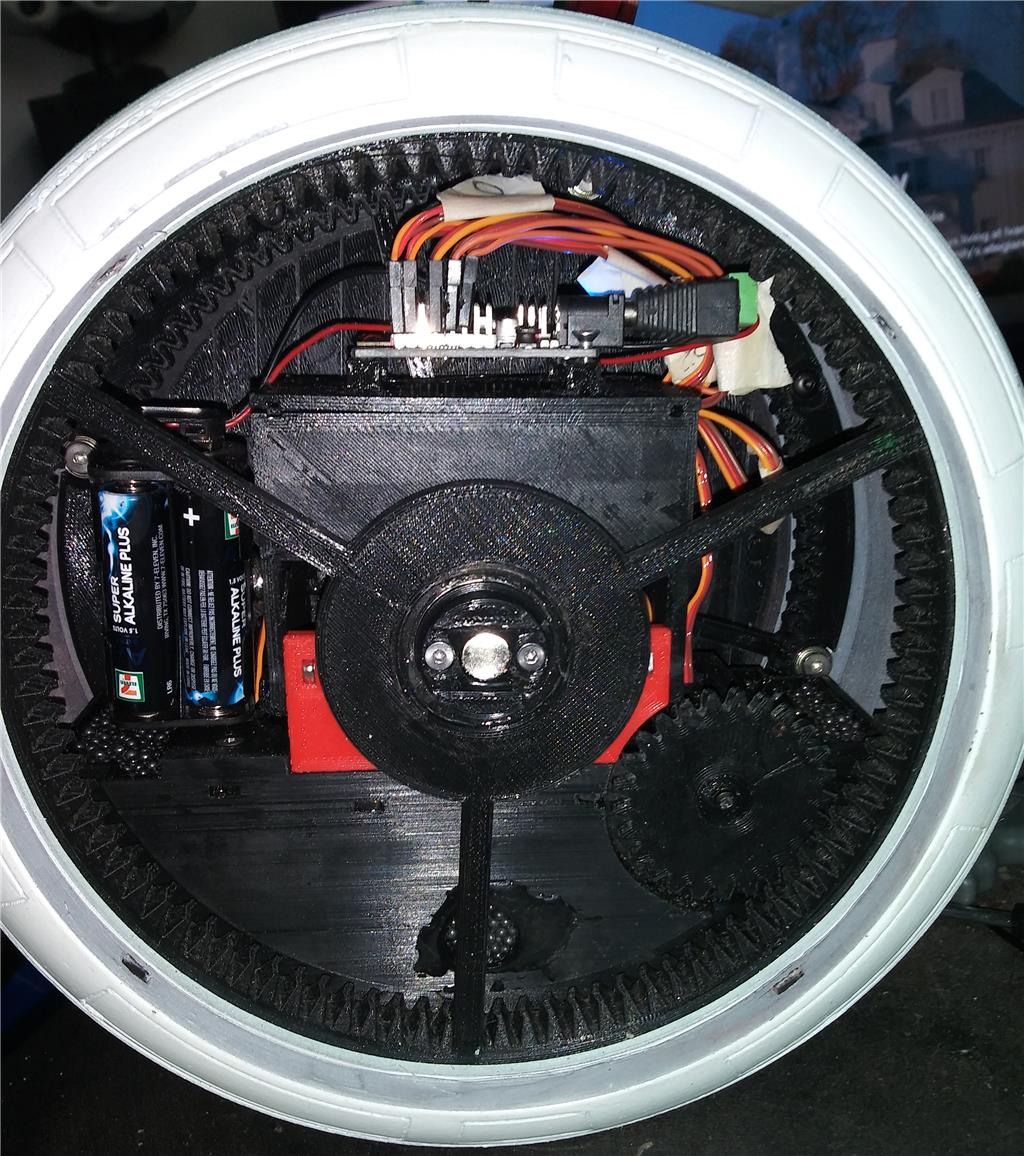
Here is my D-O droid powered by the IoTiny and controlled through my tablet.
The head is too heavy for the servo in the body, it wants to tilt forward so the nose hits the ground. so I had to lock it up. Otherwise it has the function for the bar holding up the head to tilt back and forth.
By kashyyyk
— Last update



Discover more robots
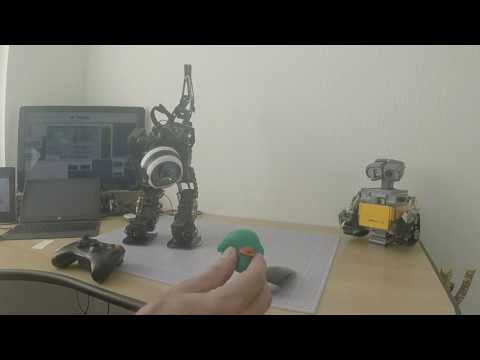
Adfe74's Meet Suki 6Dof Leg Dynamixel Ax-18A
SUKI 6-DOF biped uses inverse kinematics, IMU for future balance, blob-based ball tracking, gait sequences with dampers...
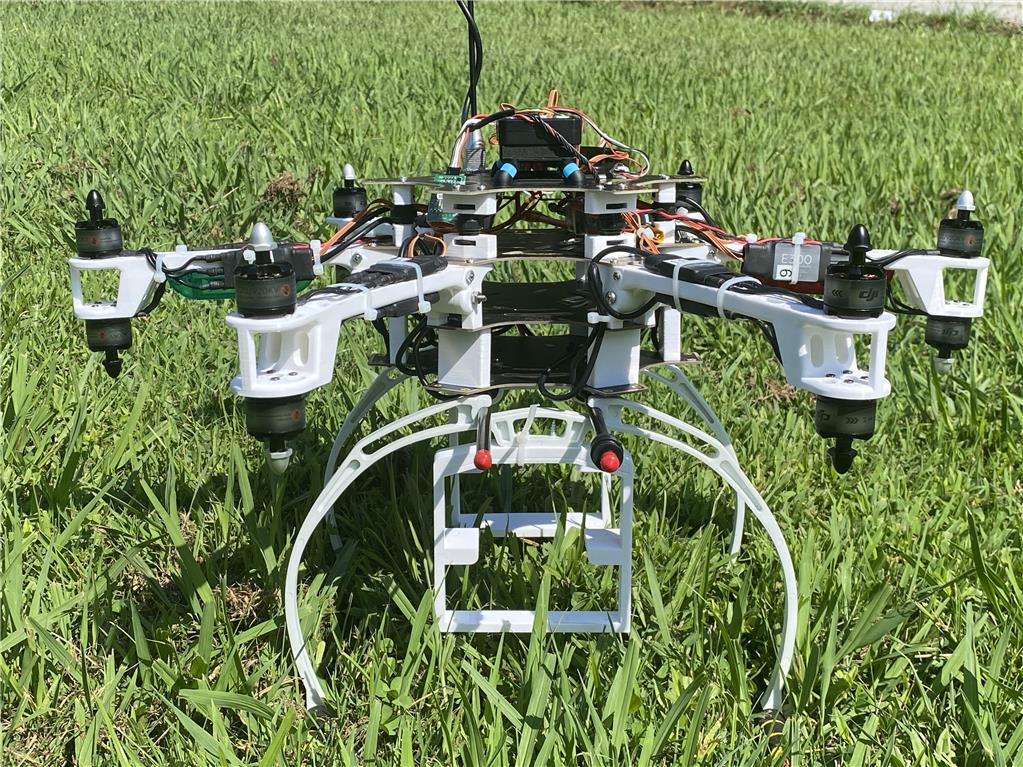
Jstarne1's Sky Anchor ,Gig Wifi Drone
Hex coaxial drone with 12 props and 15 lb thrust, 3D-printed frame to lift a WiFi antenna and camera for extended robot...
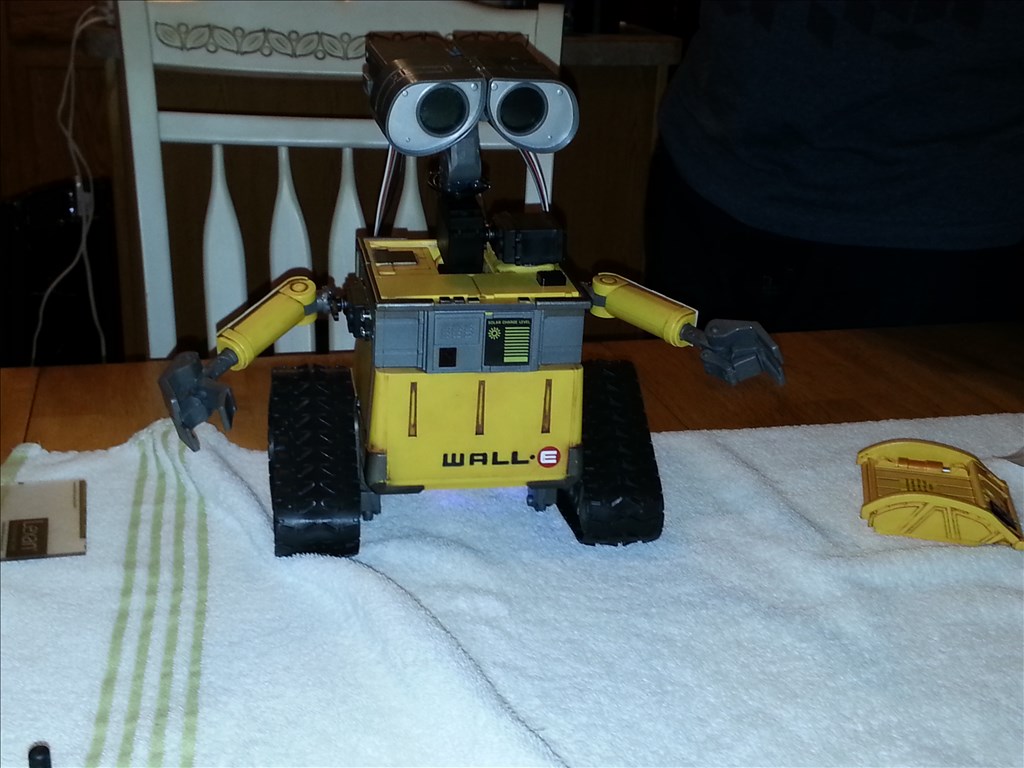
Slim6072's My Wall-E
Wire BlinkM eyes, add sonar, mount camera on head and integrate MP3 Trigger-robot nearly complete and otherwise working...

Wow! That's a 3D printing masterpiece!
That is so flip'n cool!
WoW is Right. What are you using for the counter weight. I think it looks like shot. Maybe you just need more counterweight to compensate for the Head weight. if you do not have enough room try making a solid lead weight. Have you thought of a GYRO. for balance. Thanks for showing the insides.
It has about 4 pounds of shot. The head rod is connected to a servo to tilt it back and forth, the red gear in the first image, the counter weight doesn't affect the head, only keeps the whole assemble from spinning.