





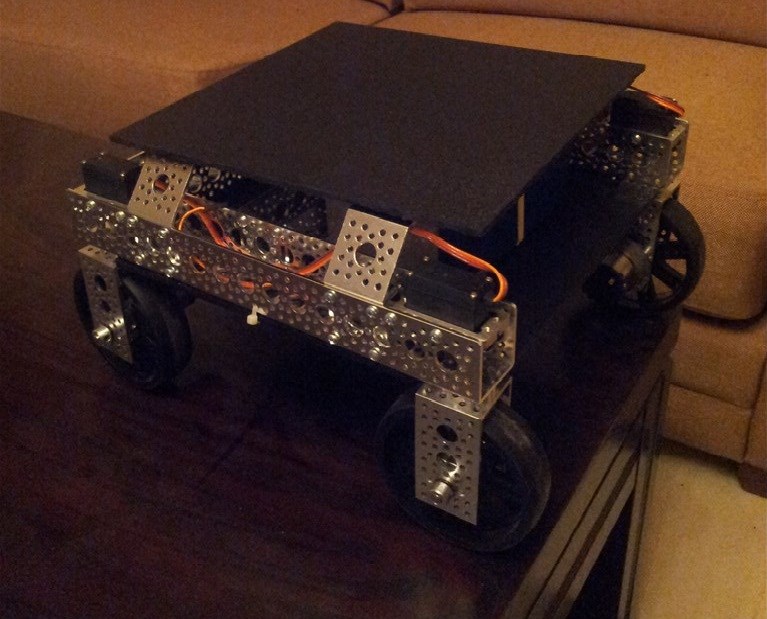
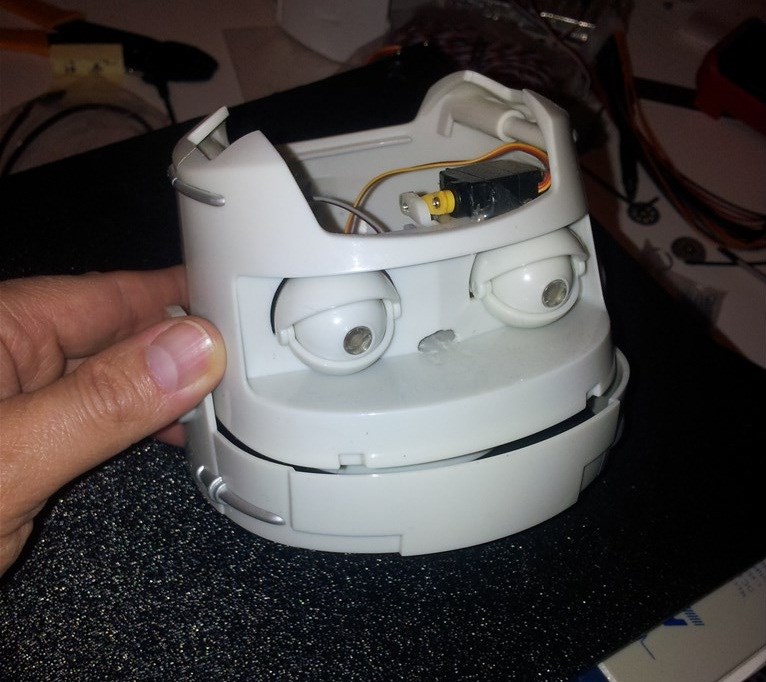
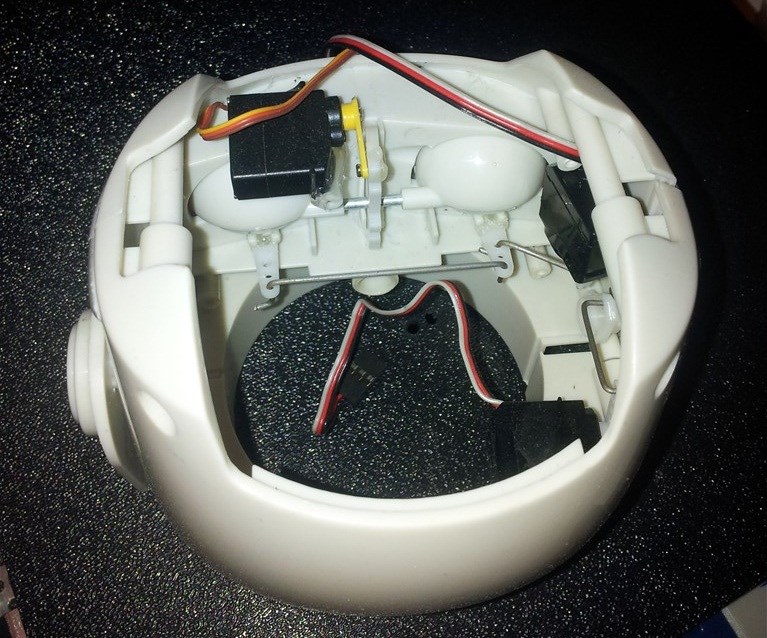


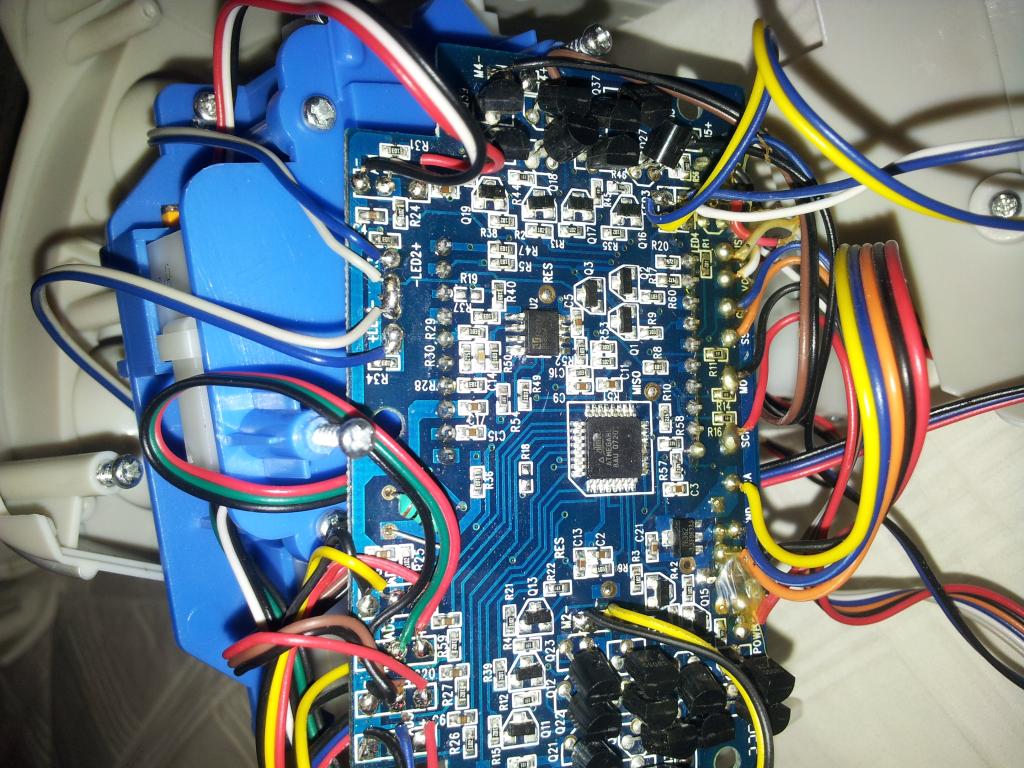




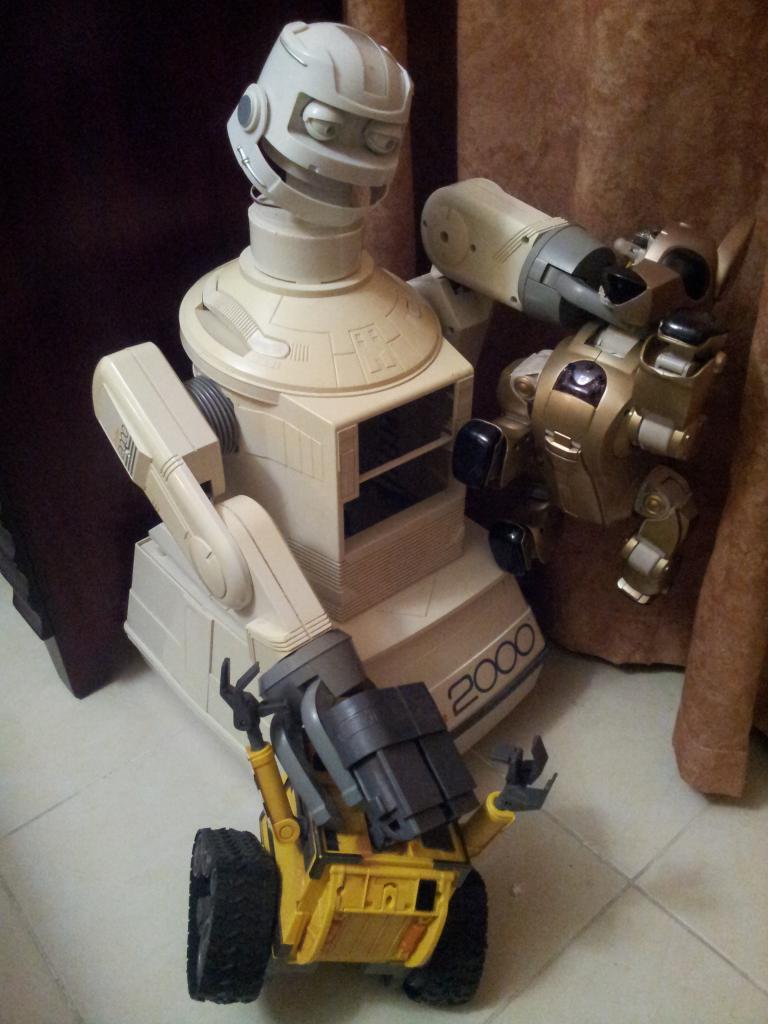
It's just a concept right now but I wanted others to see that the scale doesnt quite match. Right now its just stacked on there and neck is a little too long.
By Troy
— Last update

Discover more robots
Mickey666maus's ARC And Windows On Raspberry Pi 4
Microsoft may need to commit to ARM's rise as computing shifts, highlighting implications and skepticism about current...
DJ's Adventurebot Chasing Red Ball
Control AdventureBot with Synthiam ARC to track and chase a red ball, creating captivating vision-based robot behavior...
Ezang's Two Projects From The Past - Re-Mixed
Detect faces or absence of faces and play robot sound files when red is detected in Justin's remixed projects.

Don't tell me that, I must have one for my hearoid build now!..
Hey Troy! I'm glad to see you back at it! Pinhead needs to be finished...Is the joystick a new controller or a used one? Perhaps there is a problem with the contacts?
Problem is getting even a cheap mr clock radio will set you back 50 bucks but I see them for sale for 80 to 100 online lol. Ya know I just so happen to know a guy who might have a mr clock radio and a clear helmet front.
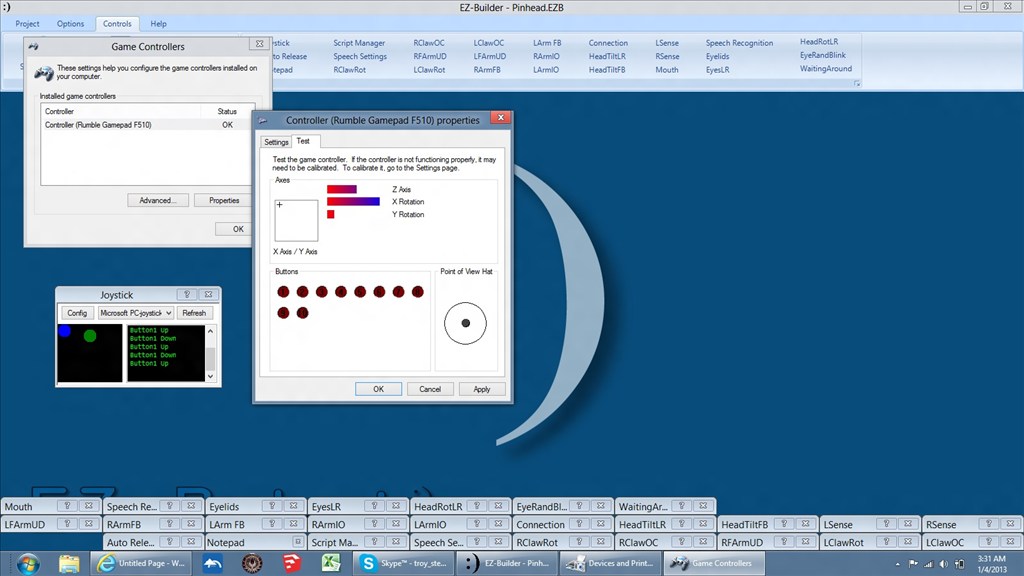
Bret, its a new joystick. It works fine hardware wise because I see it move on the Windows devices/ device properties.

Here I'm moving the left joystick to top left and right joystick to top right.Update. I noticed that the left trigger moves the green dot all right and right trigger to all left.
Update#2 blush Nevermind blush I missed switch on the underside of the stick that fixed it. But in my defense, the screenshot showed it working,
hahahahaha - Glad to see you figured it out.
As you can see. The neck tilt forward and back oscillates. There is a little play in the joint but also the connection at the base isn't sturdy enough. As soon as my new part comes in I will replace it.
Btw those are motion sensors on the ears lol.
it looks very good,nice JOB TROY