





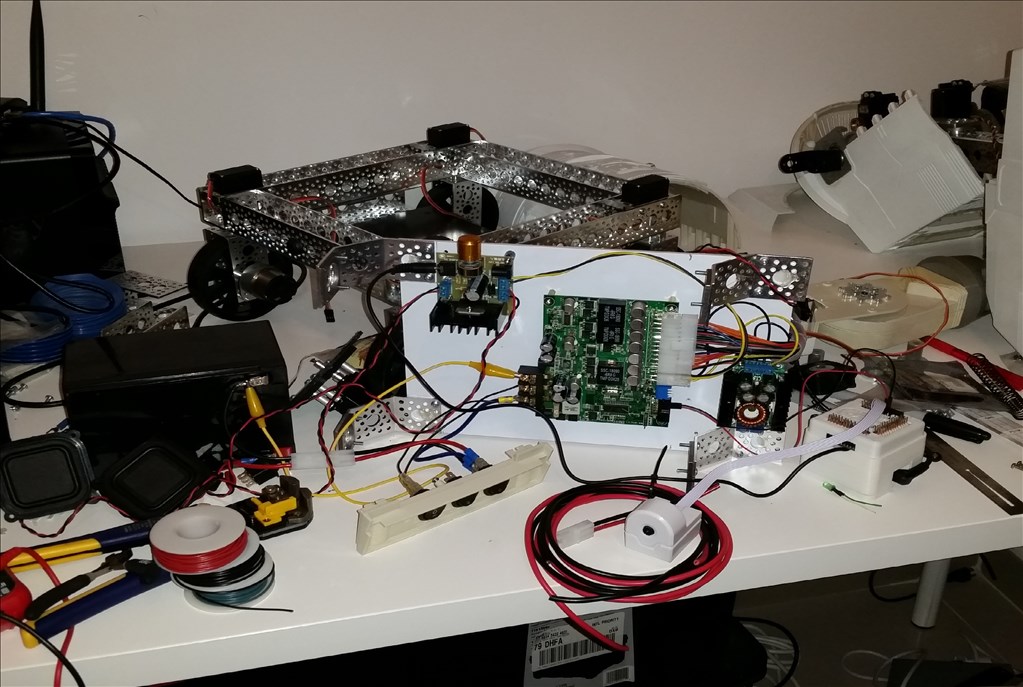
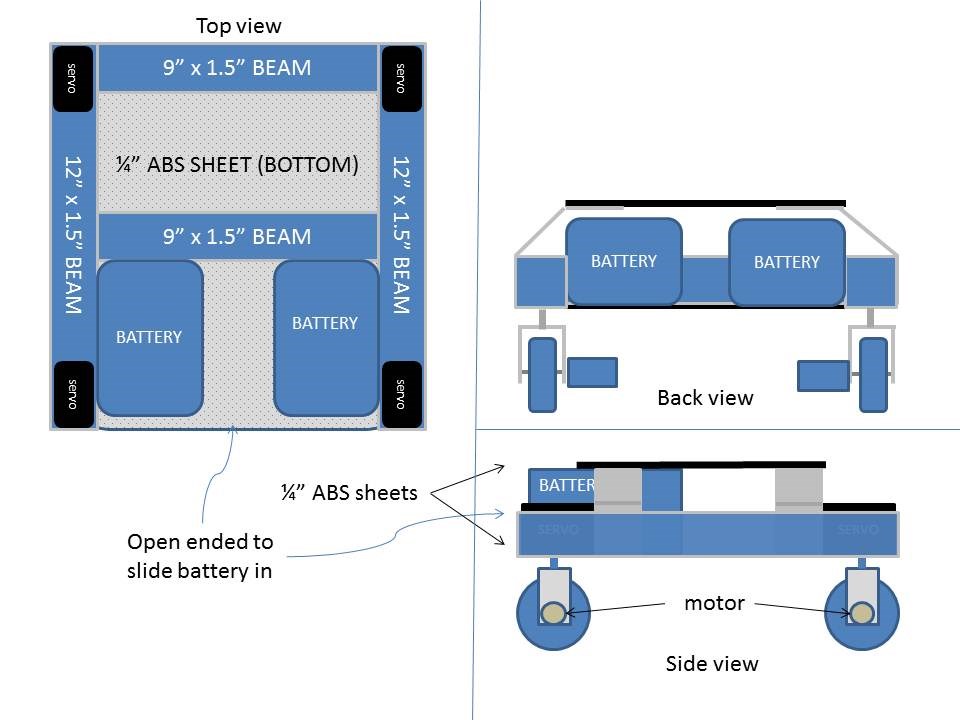
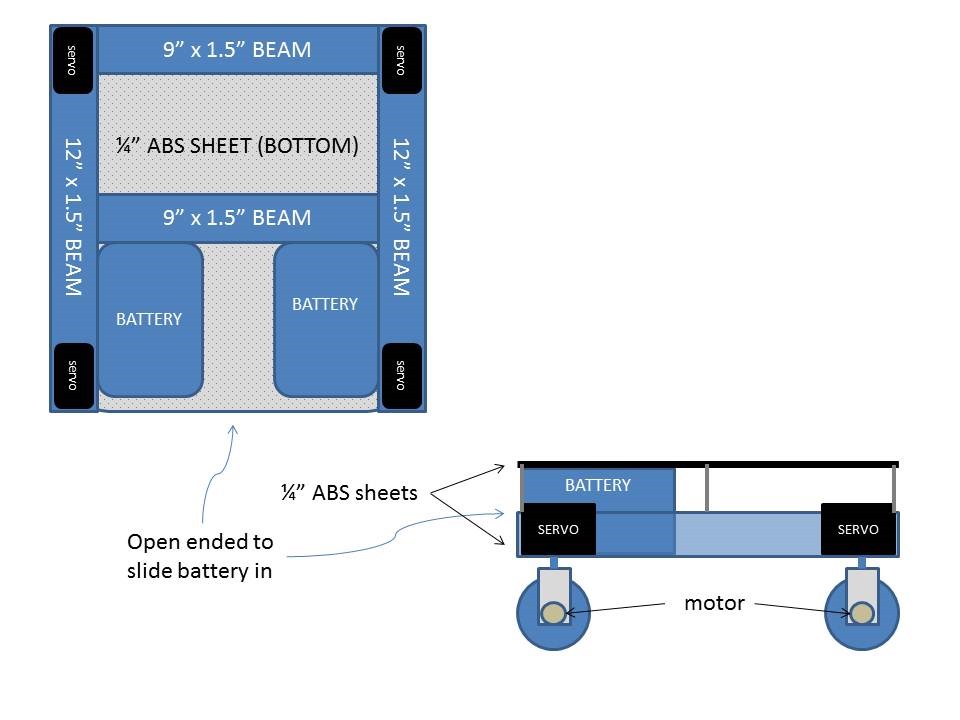
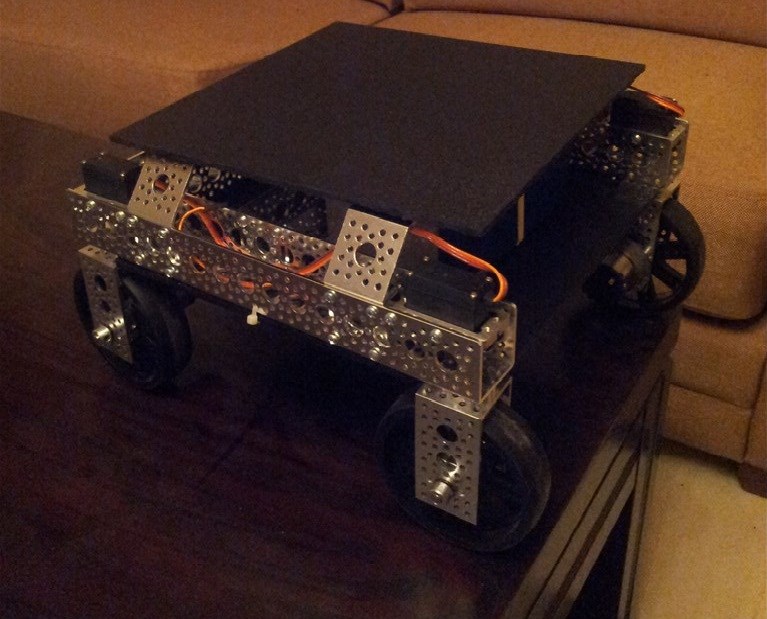
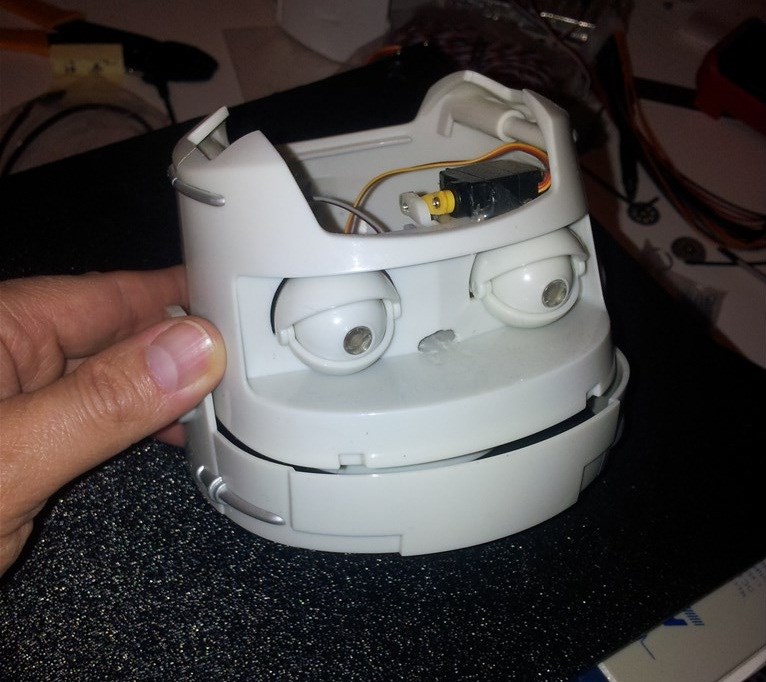
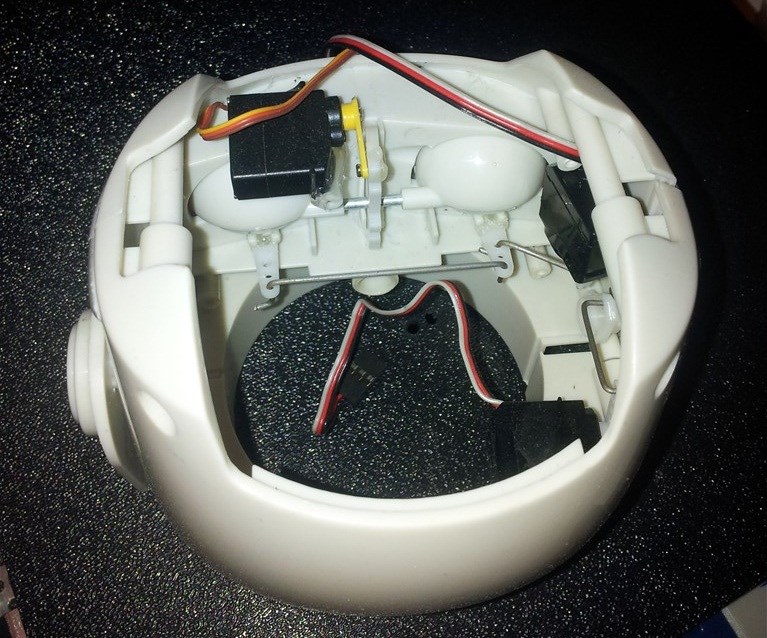


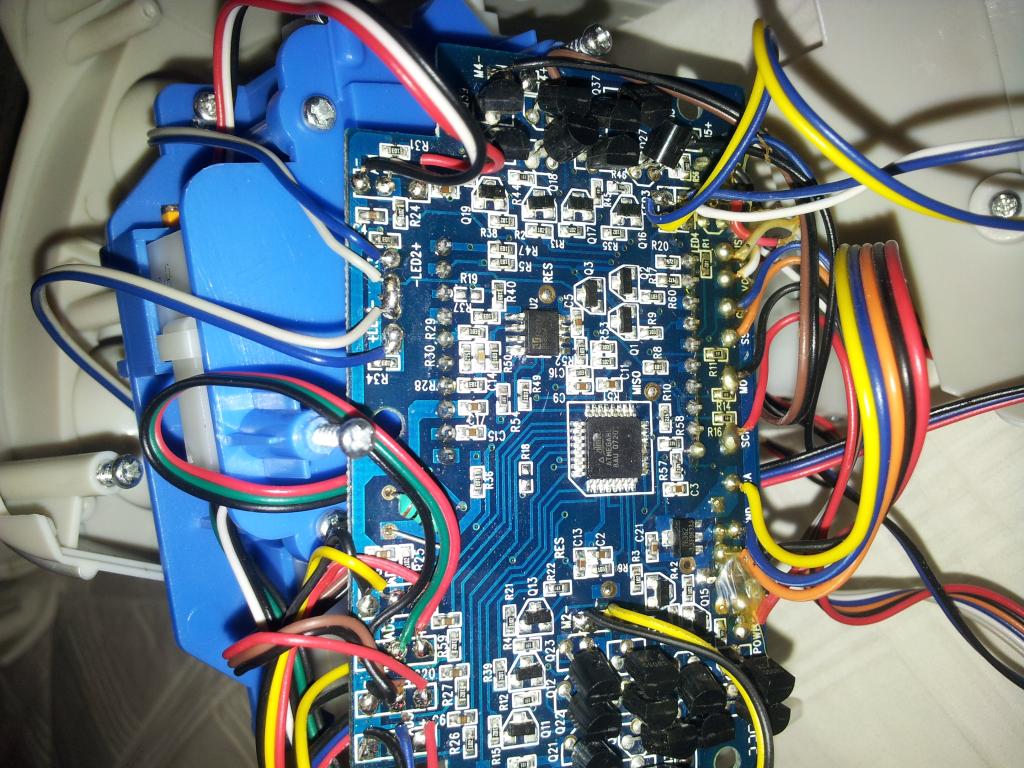
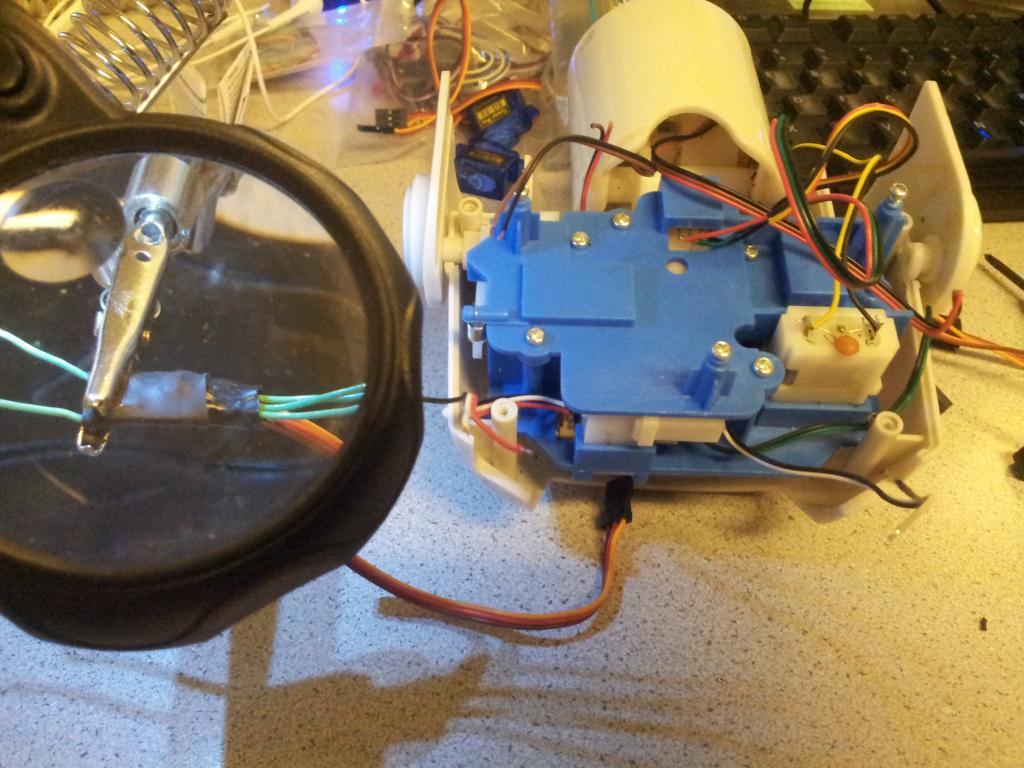
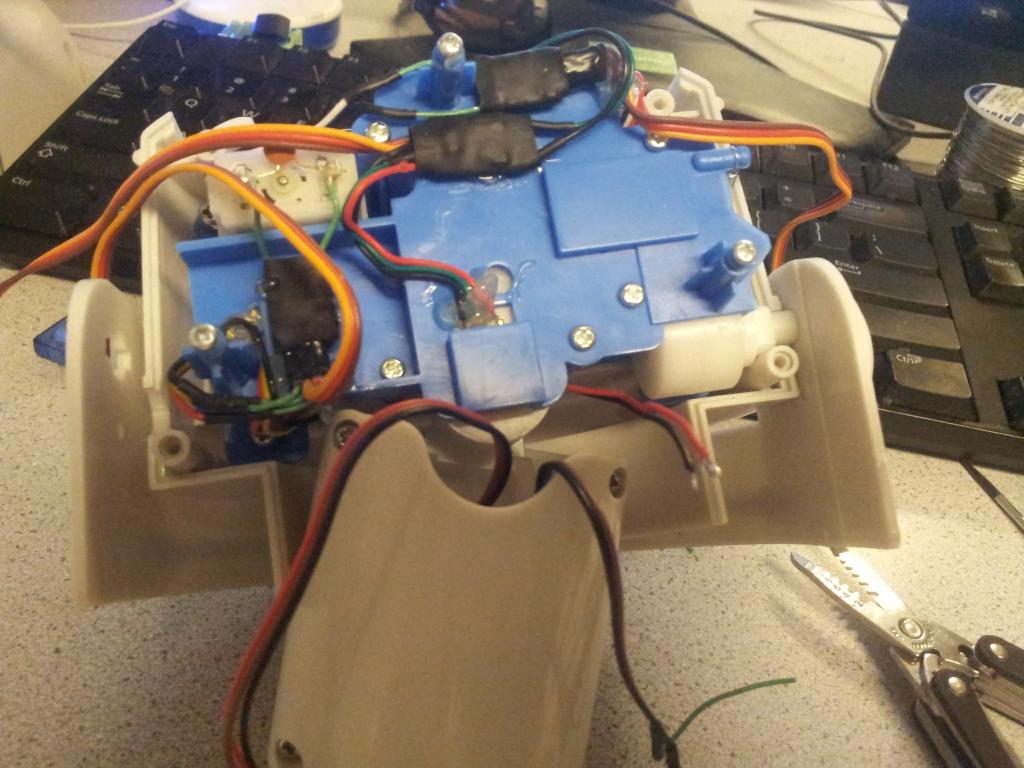

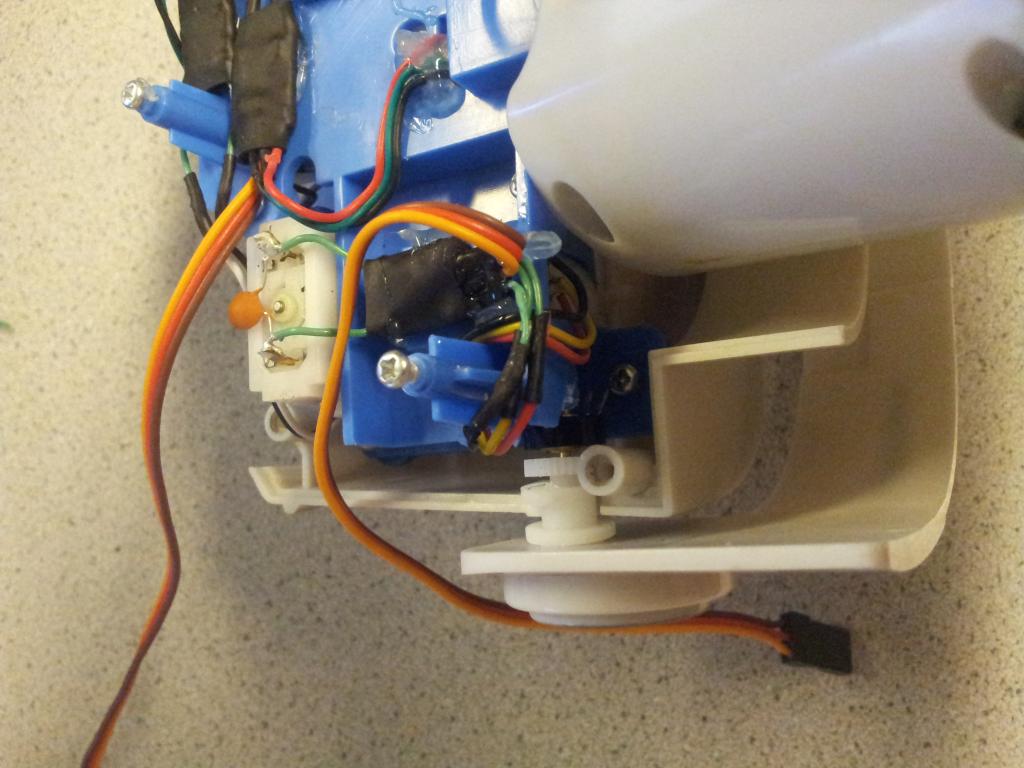

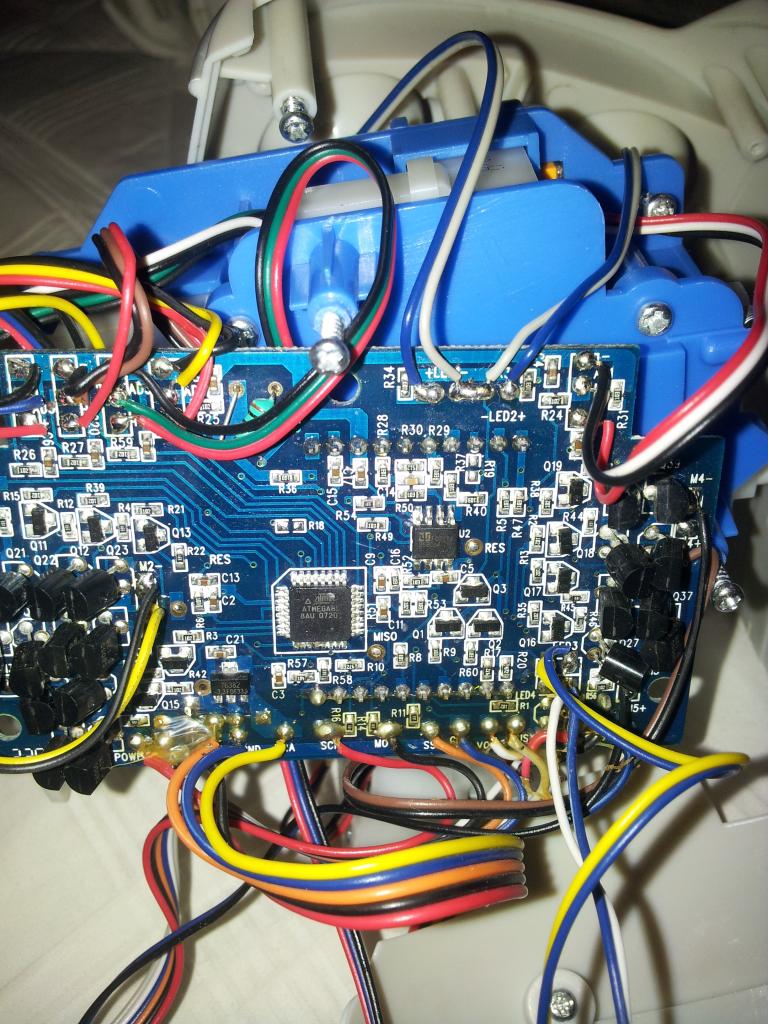
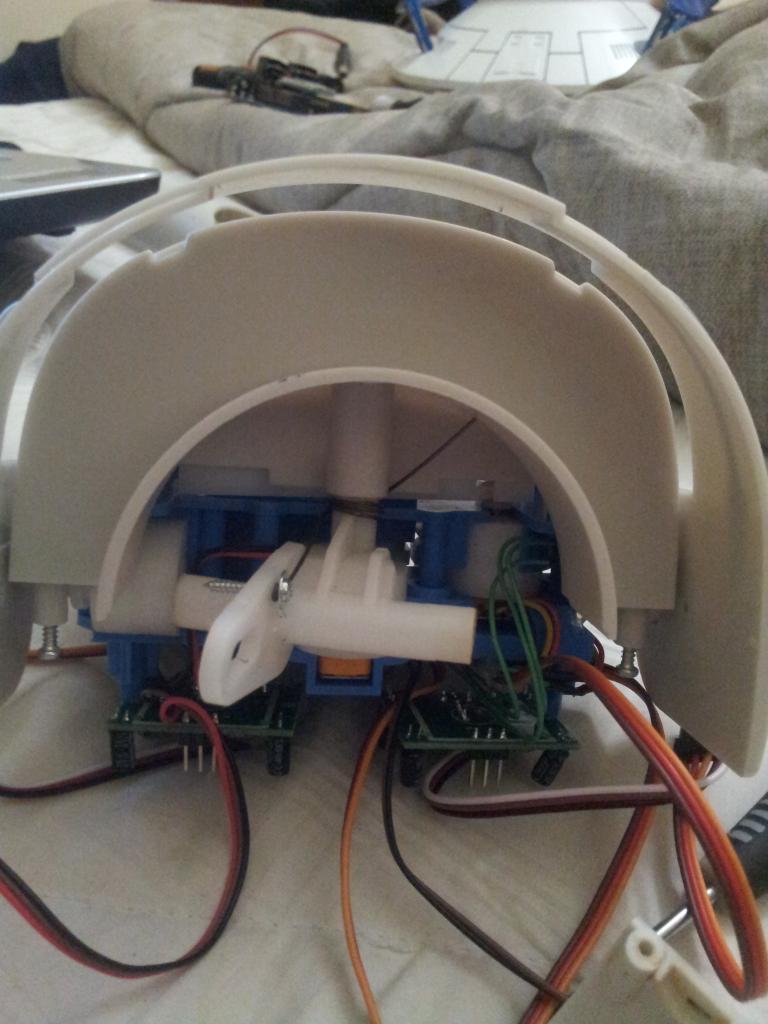


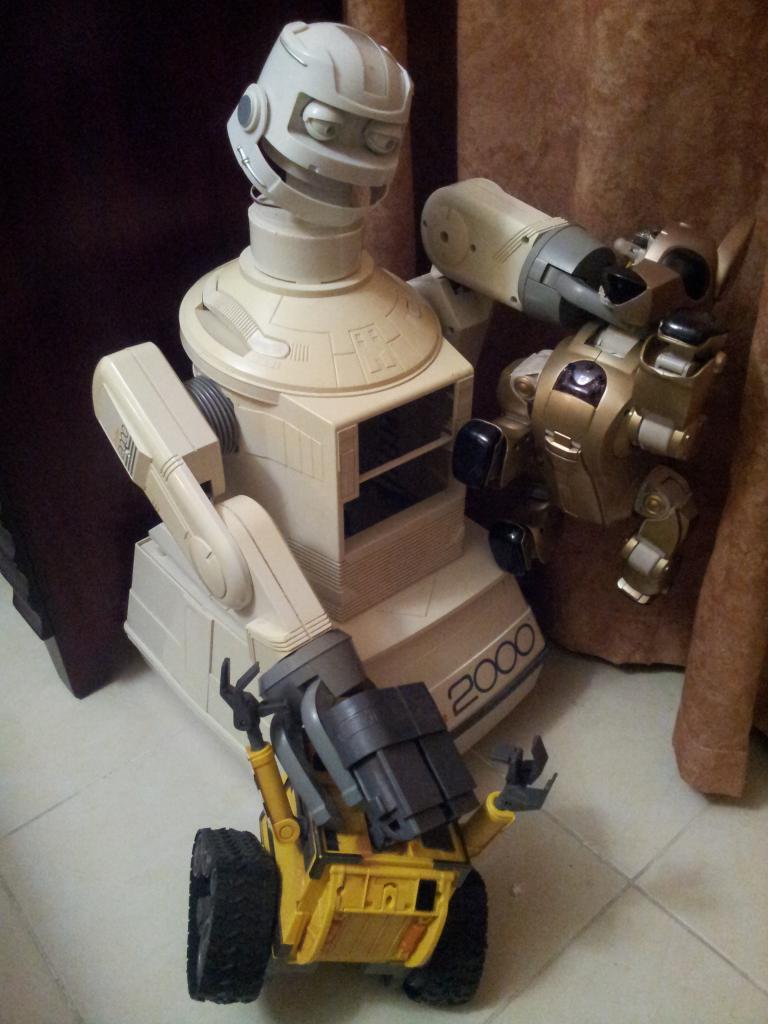
It's just a concept right now but I wanted others to see that the scale doesnt quite match. Right now its just stacked on there and neck is a little too long.
By Troy
— Last update

Discover more robots
Mickey666maus's ARC And Windows On Raspberry Pi 4
Microsoft may need to commit to ARM's rise as computing shifts, highlighting implications and skepticism about current...
Steve's 2 Ft Biped Walking(Shuffle) Robot
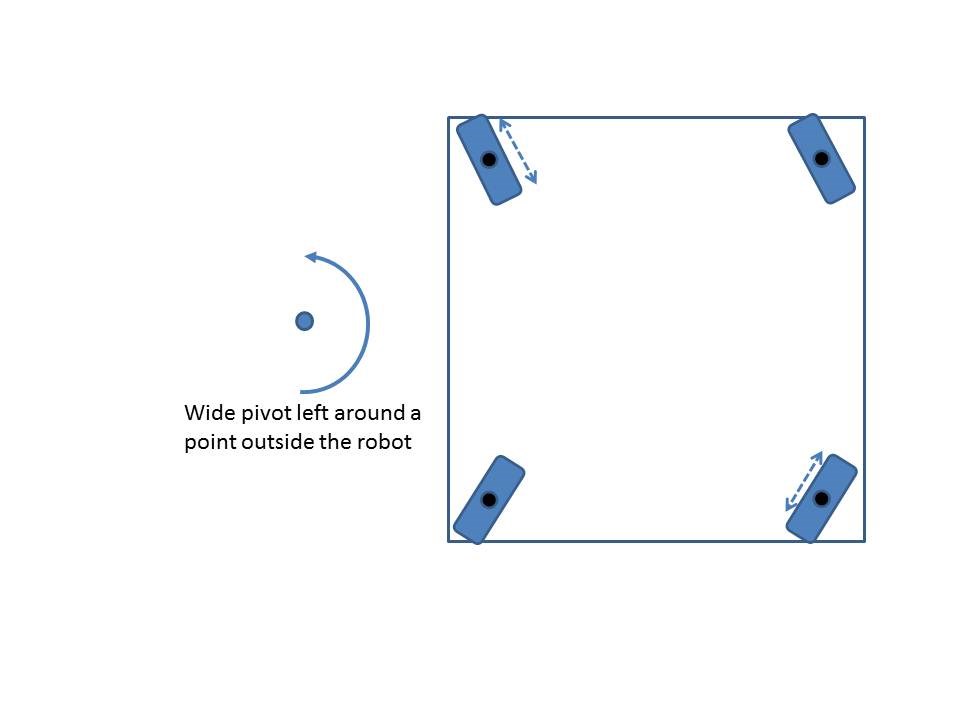
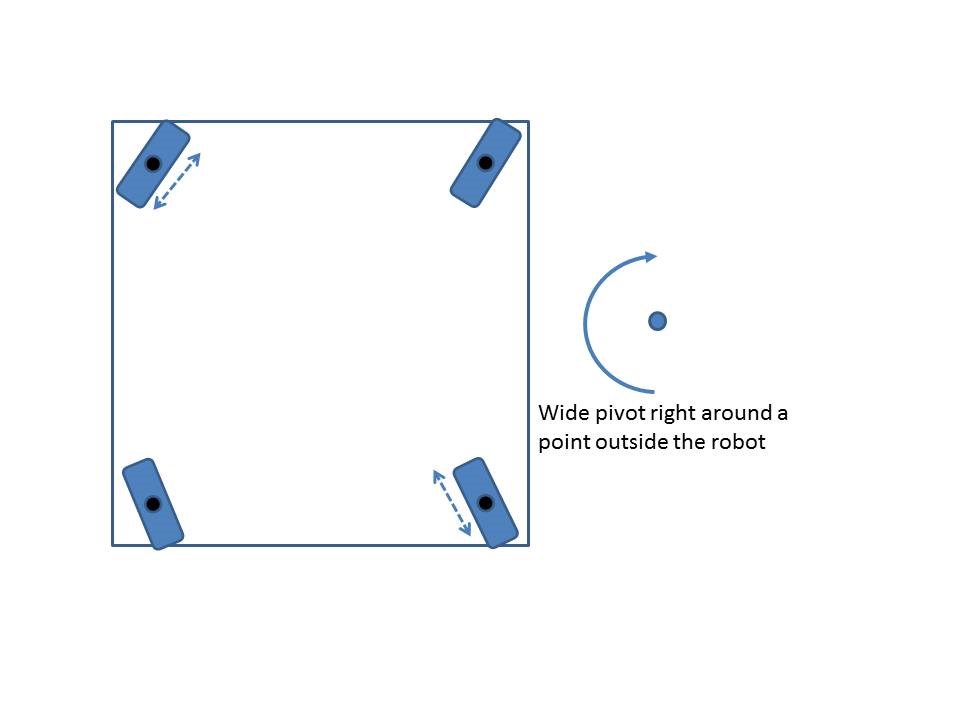
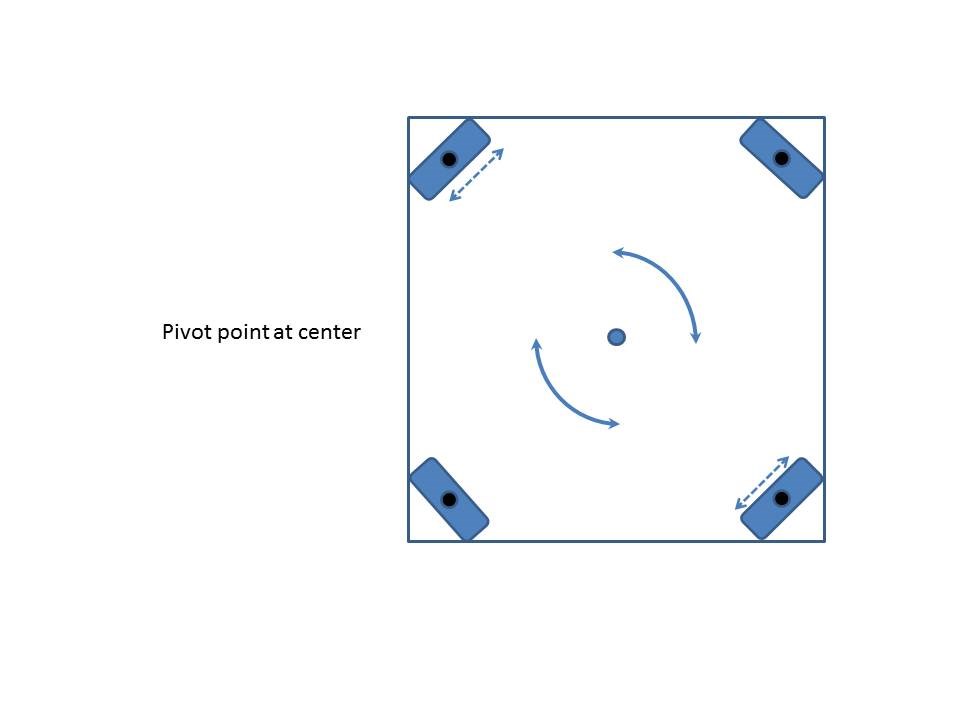
Omni-wheel robot build: overcome turning and weight distribution with center-pivot knees/hips; PVC construction and...
Bhouston's Bob's Inmoov
InMoov robot running on EZ-Robot: project recaps, links to original builds and ongoing updates

Don't tell me that, I must have one for my hearoid build now!..
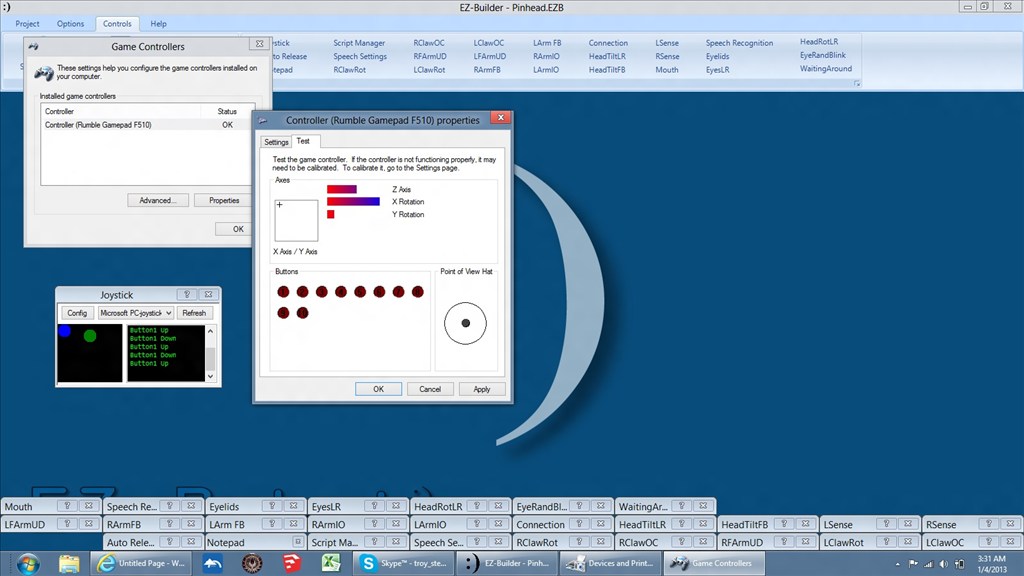
Hey Troy! I'm glad to see you back at it! Pinhead needs to be finished...Is the joystick a new controller or a used one? Perhaps there is a problem with the contacts?
Problem is getting even a cheap mr clock radio will set you back 50 bucks but I see them for sale for 80 to 100 online lol. Ya know I just so happen to know a guy who might have a mr clock radio and a clear helmet front.
Bret, its a new joystick. It works fine hardware wise because I see it move on the Windows devices/ device properties.

Here I'm moving the left joystick to top left and right joystick to top right.Update. I noticed that the left trigger moves the green dot all right and right trigger to all left.
Update#2 blush Nevermind blush I missed switch on the underside of the stick that fixed it. But in my defense, the screenshot showed it working,
hahahahaha - Glad to see you figured it out.
As you can see. The neck tilt forward and back oscillates. There is a little play in the joint but also the connection at the base isn't sturdy enough. As soon as my new part comes in I will replace it.
Btw those are motion sensors on the ears lol.
it looks very good,nice JOB TROY