

cE9s4PsOgeBQIORwjd5!~~60_1-634818020230156250.jpg)



Lupuc4g~~60_35-634706297915000000.jpg)


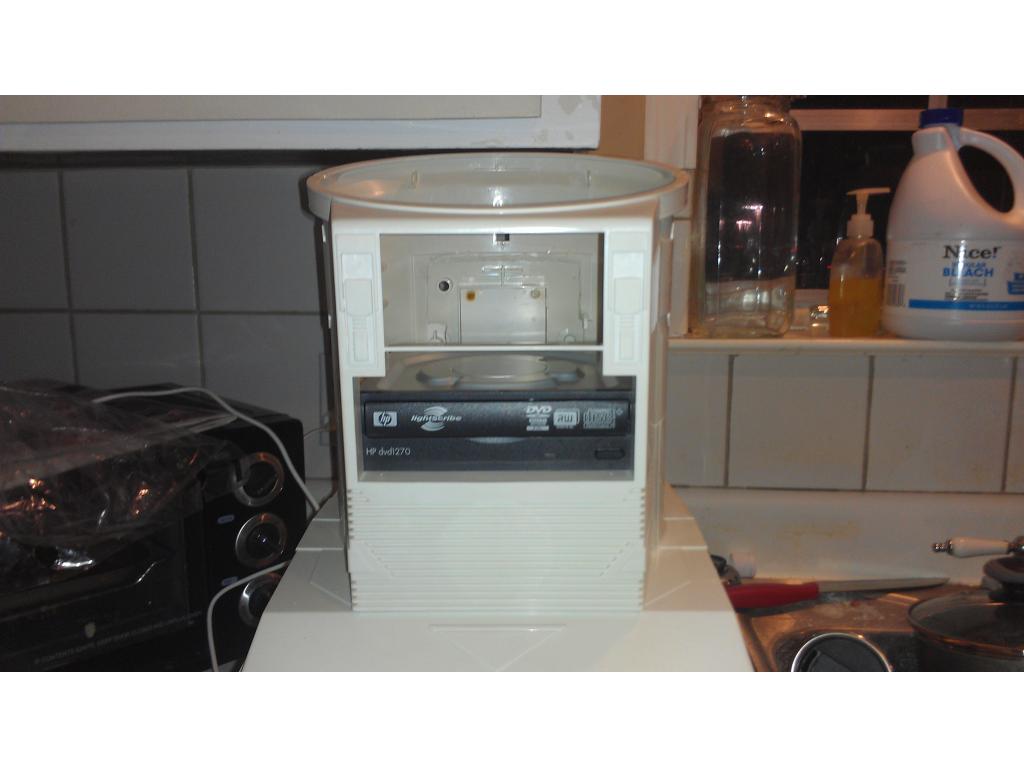
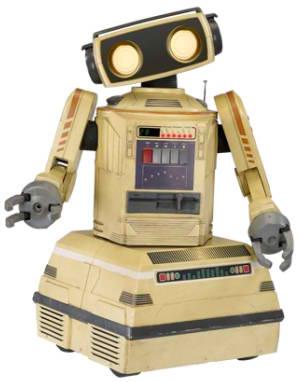
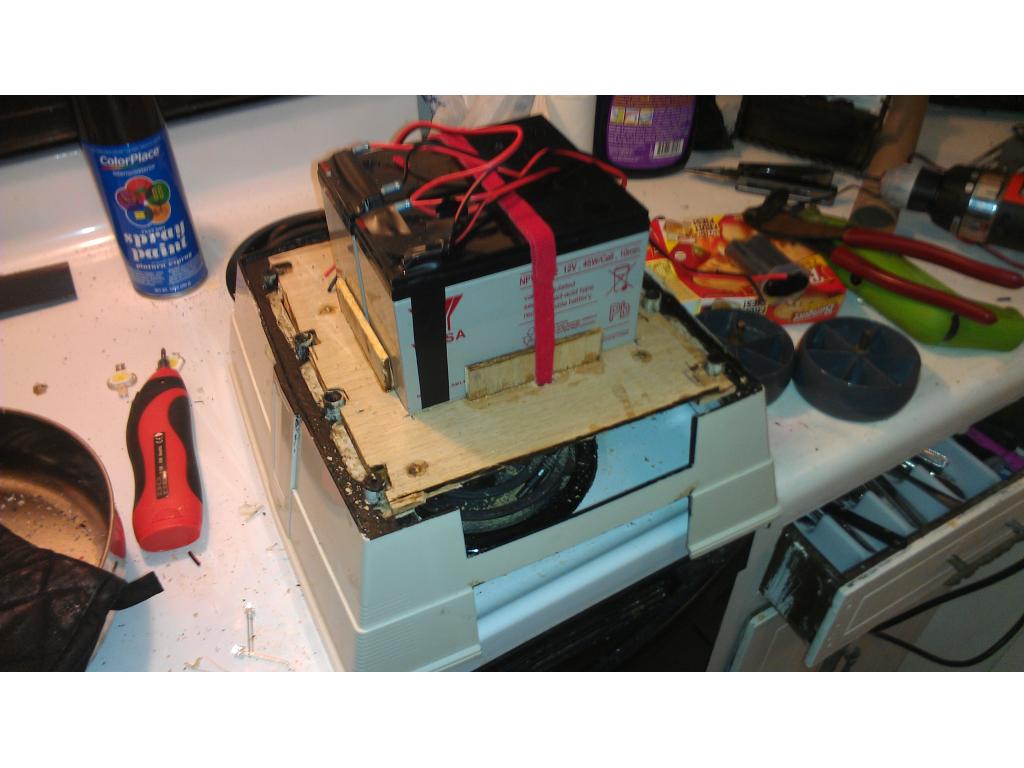

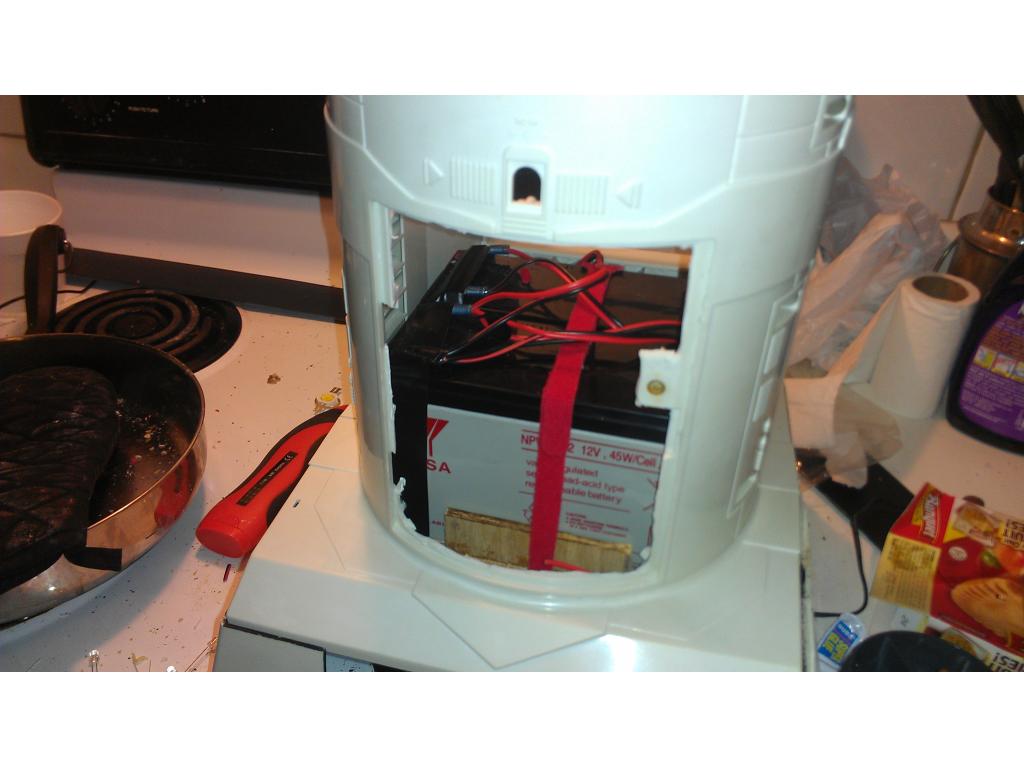
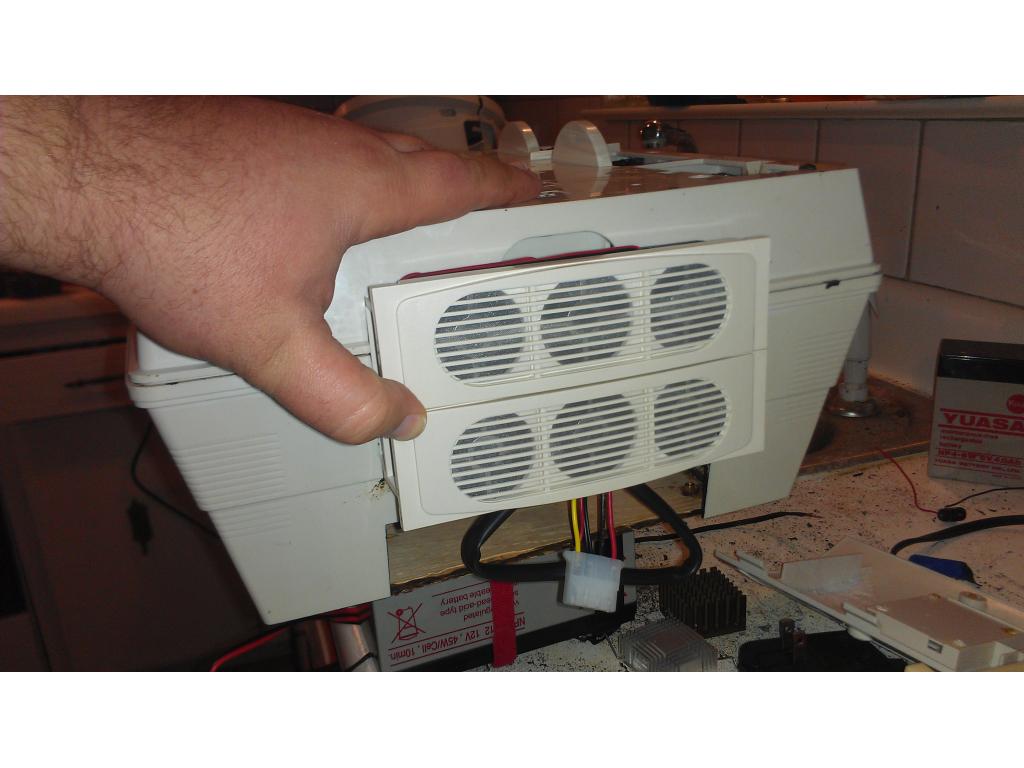
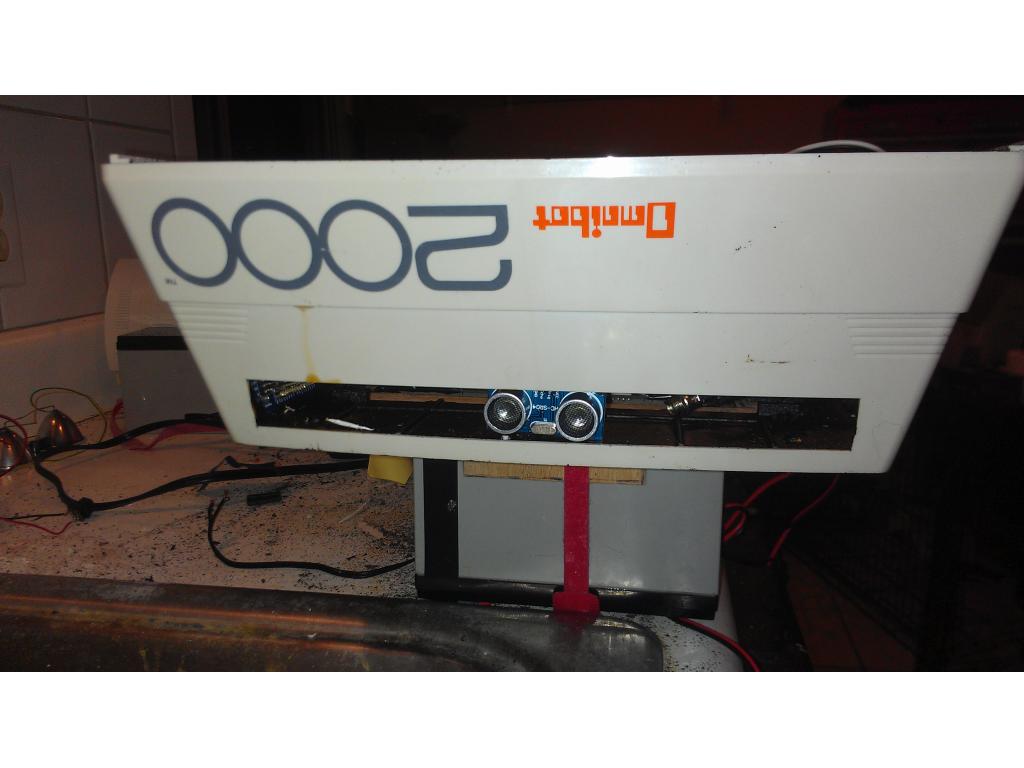
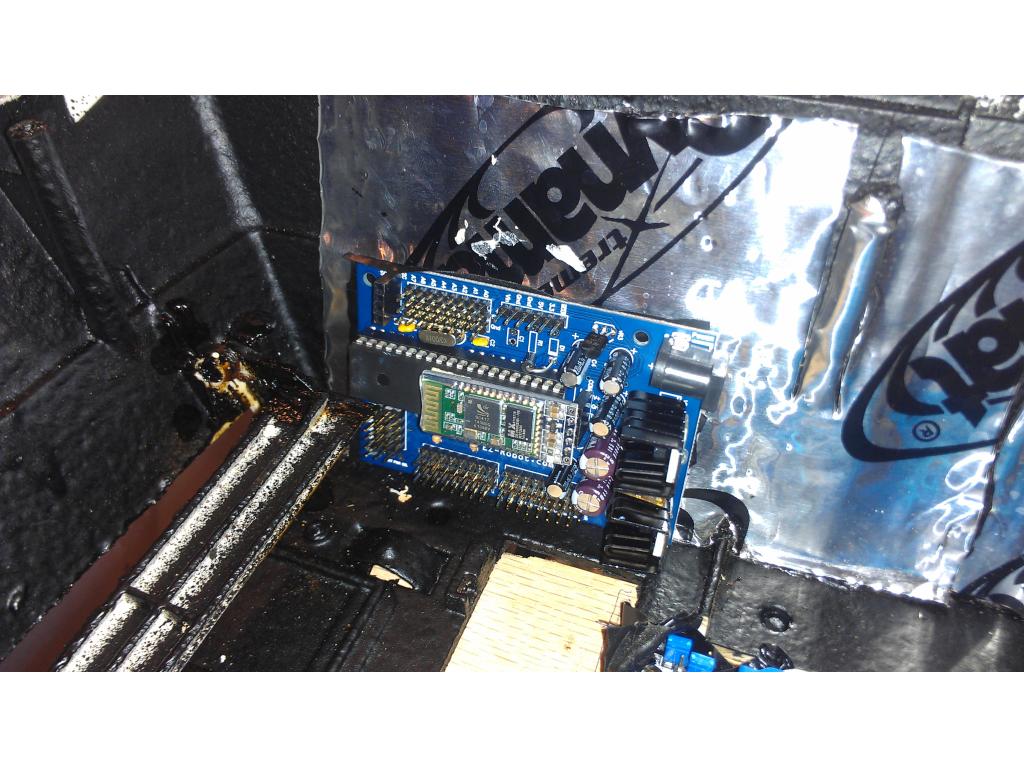

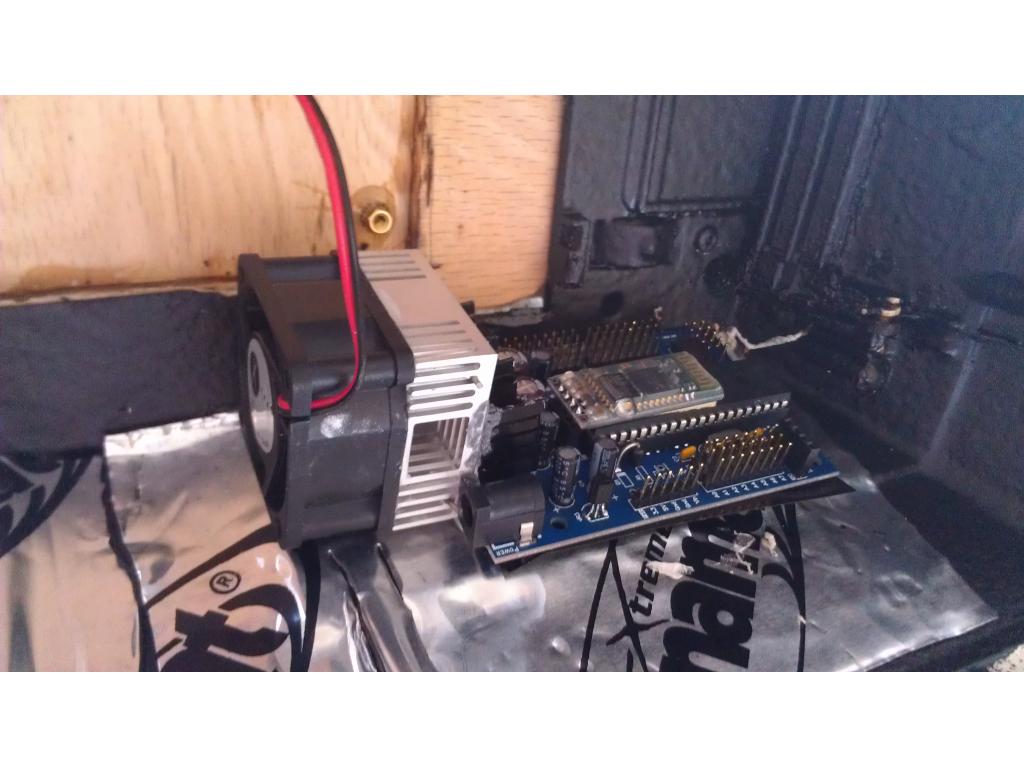
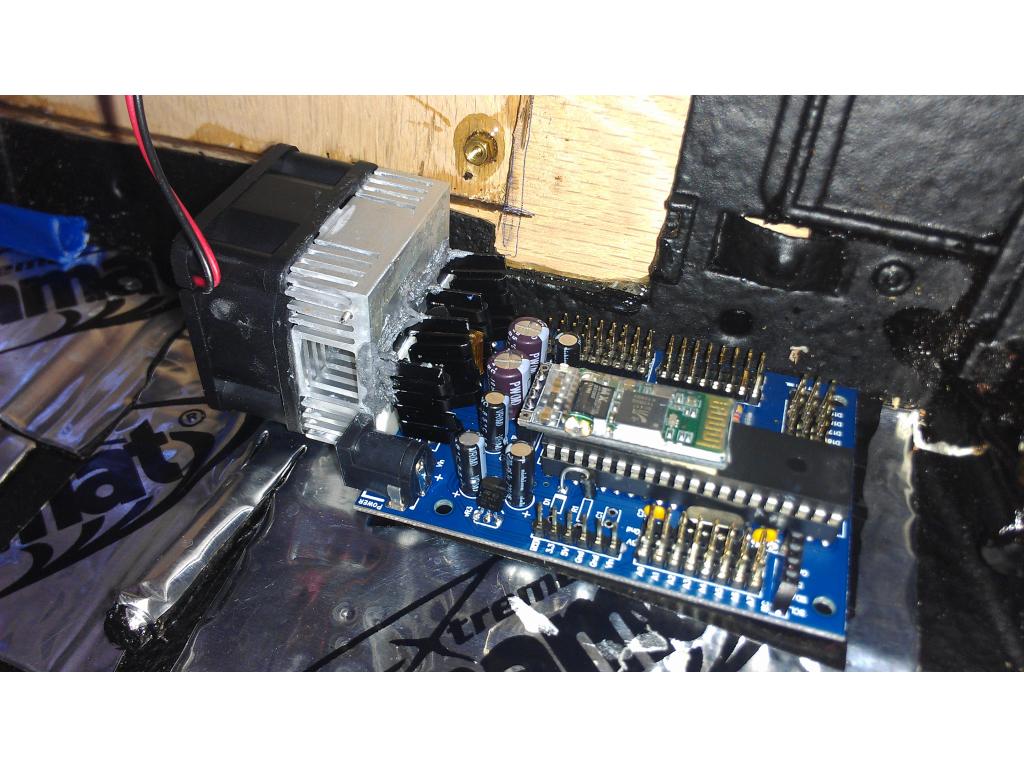

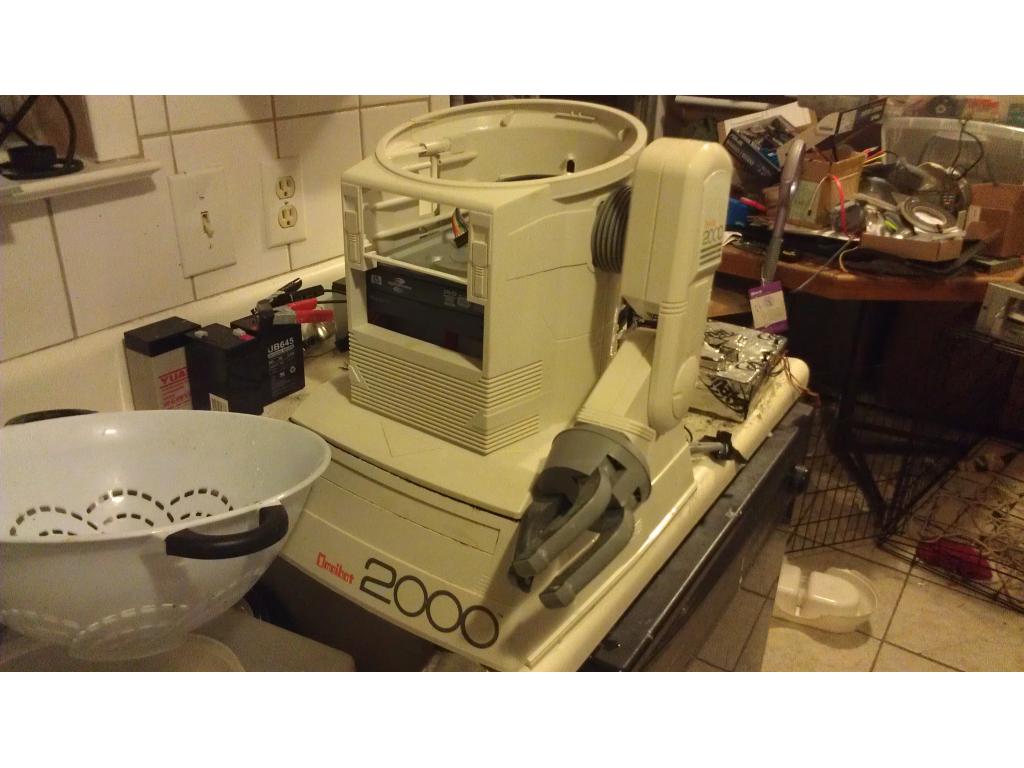
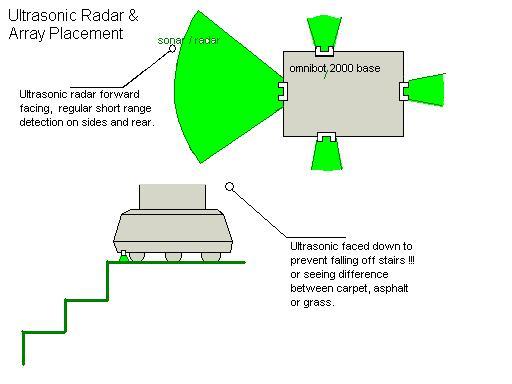
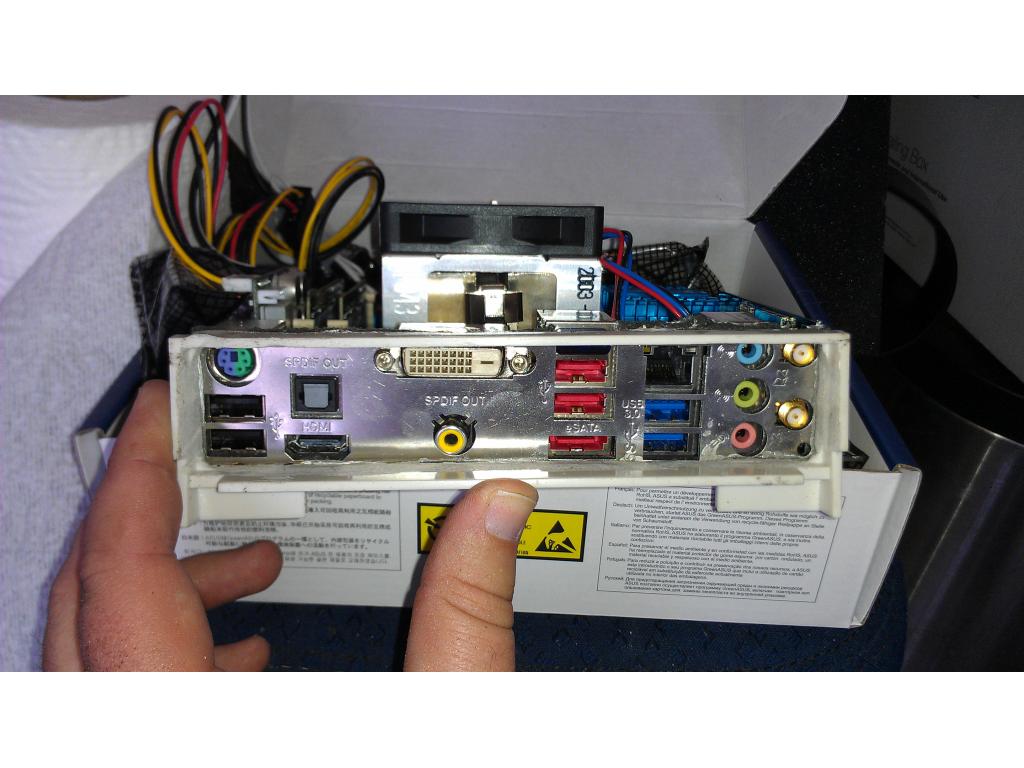
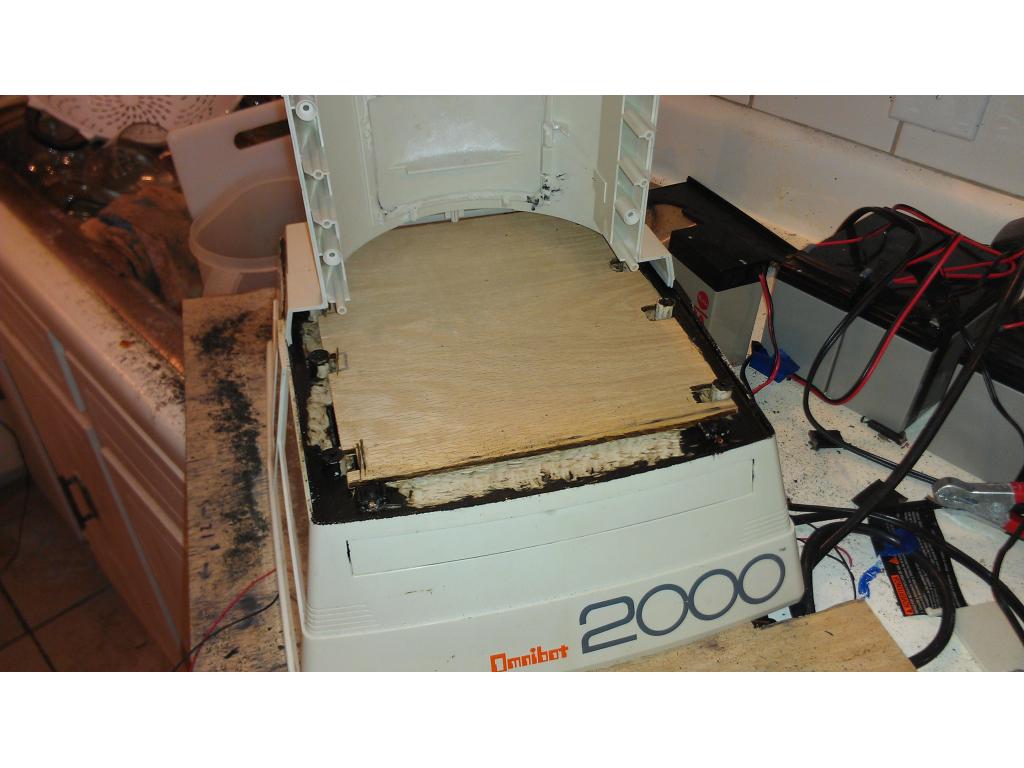
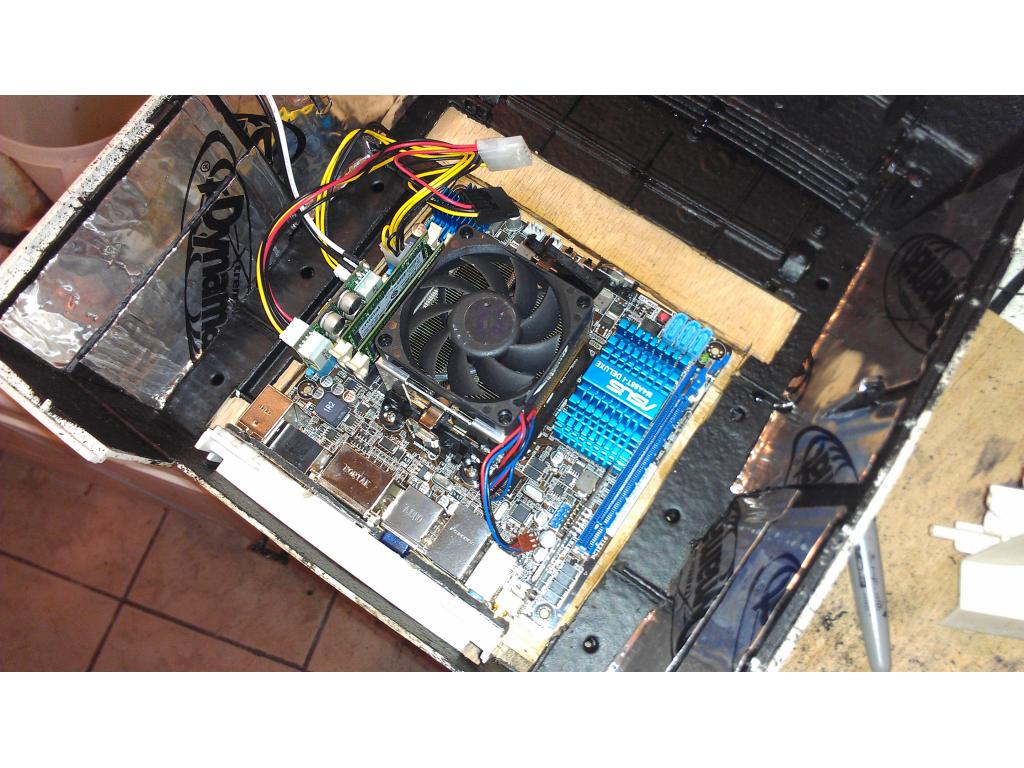
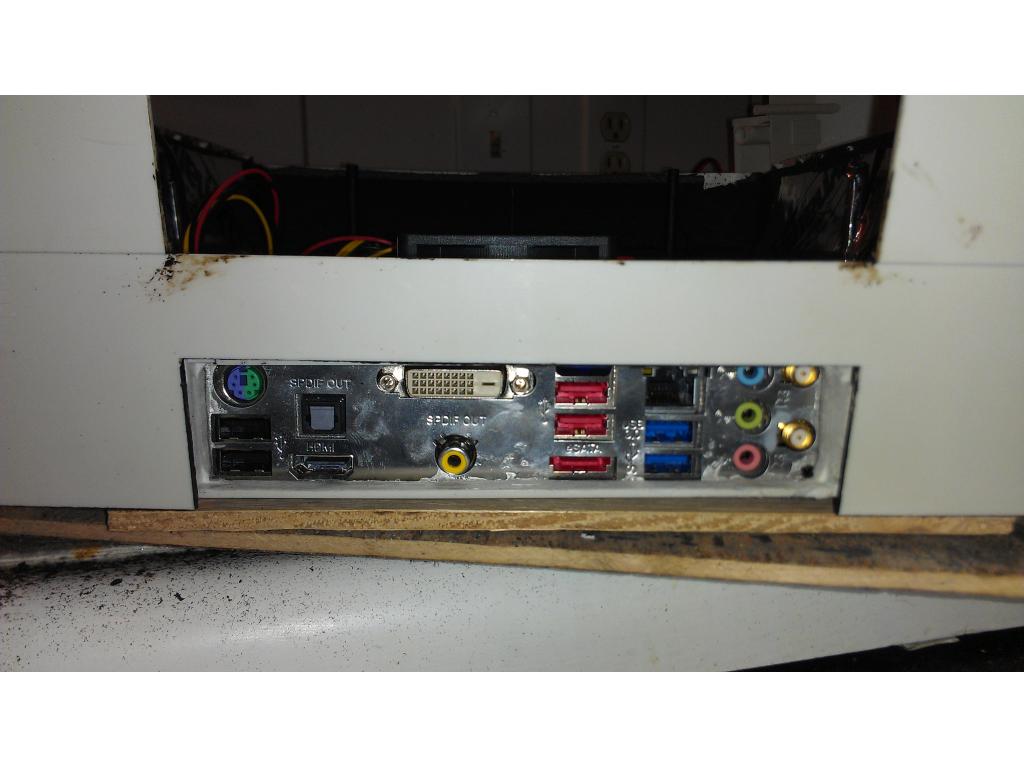
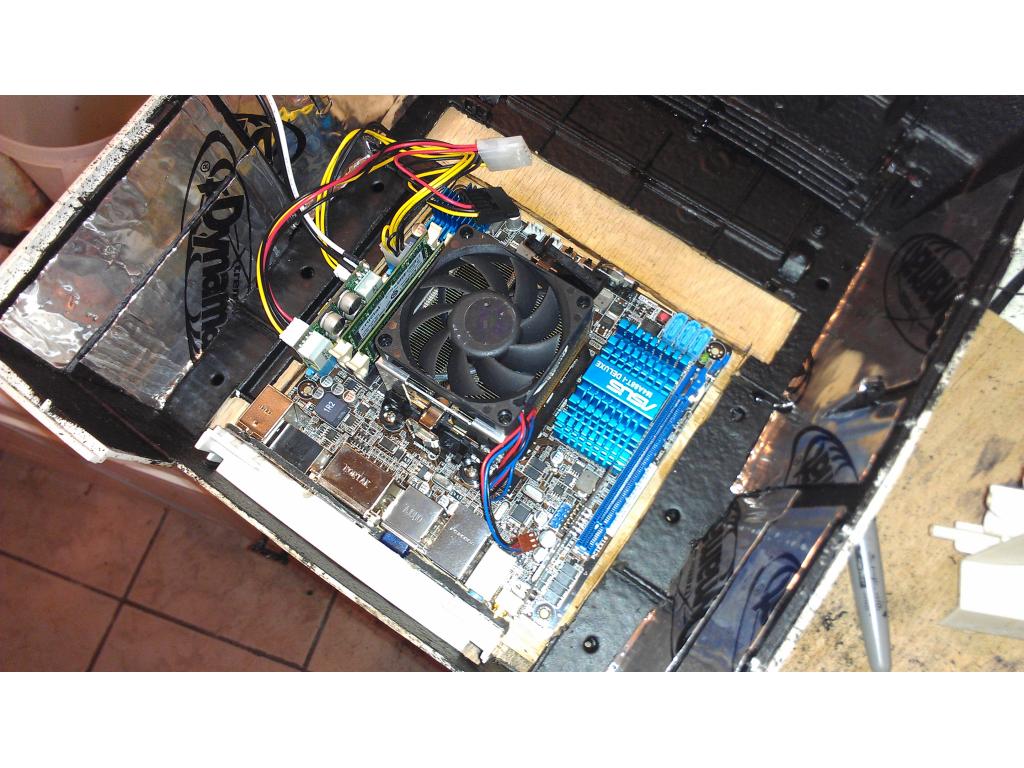
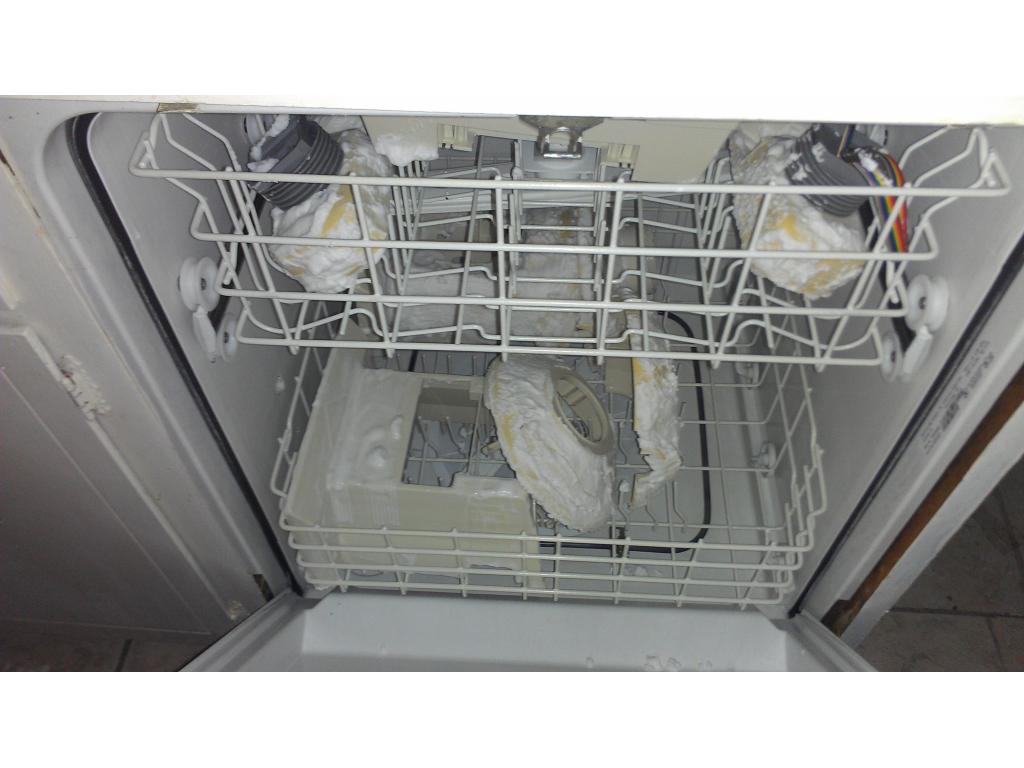
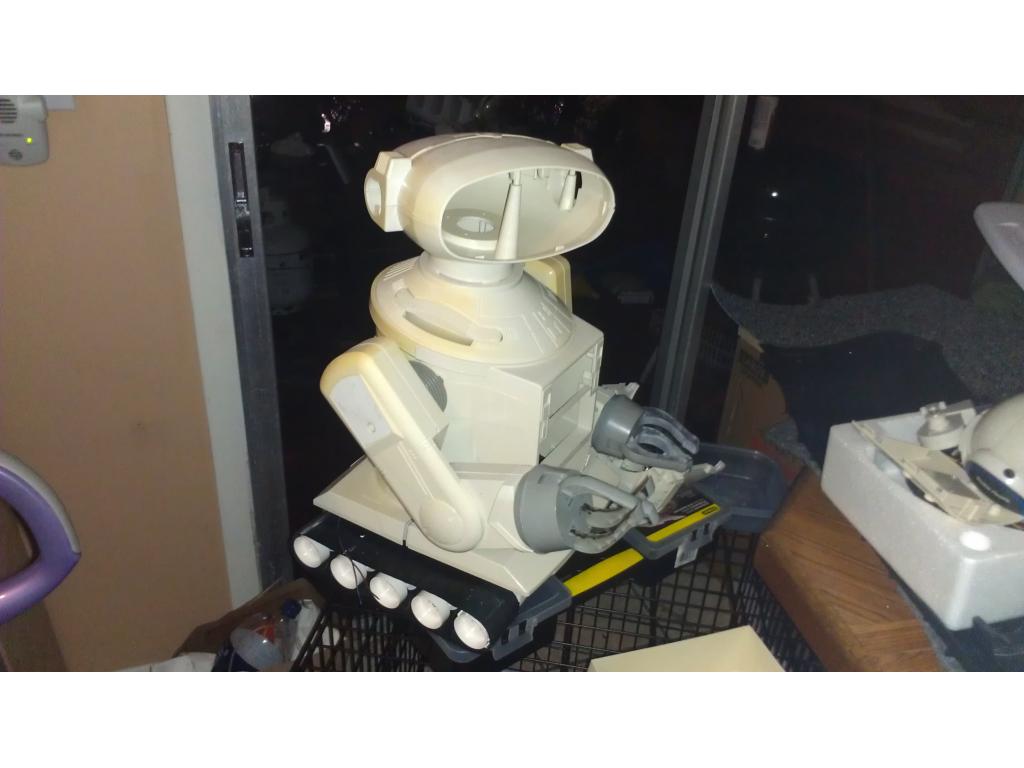
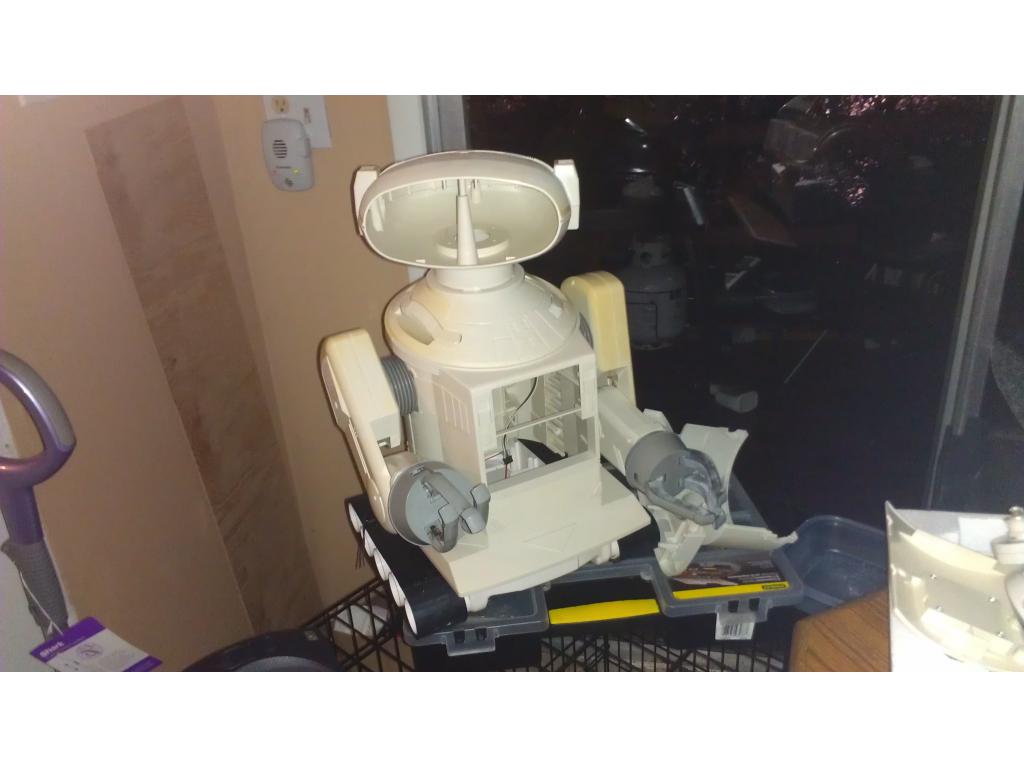
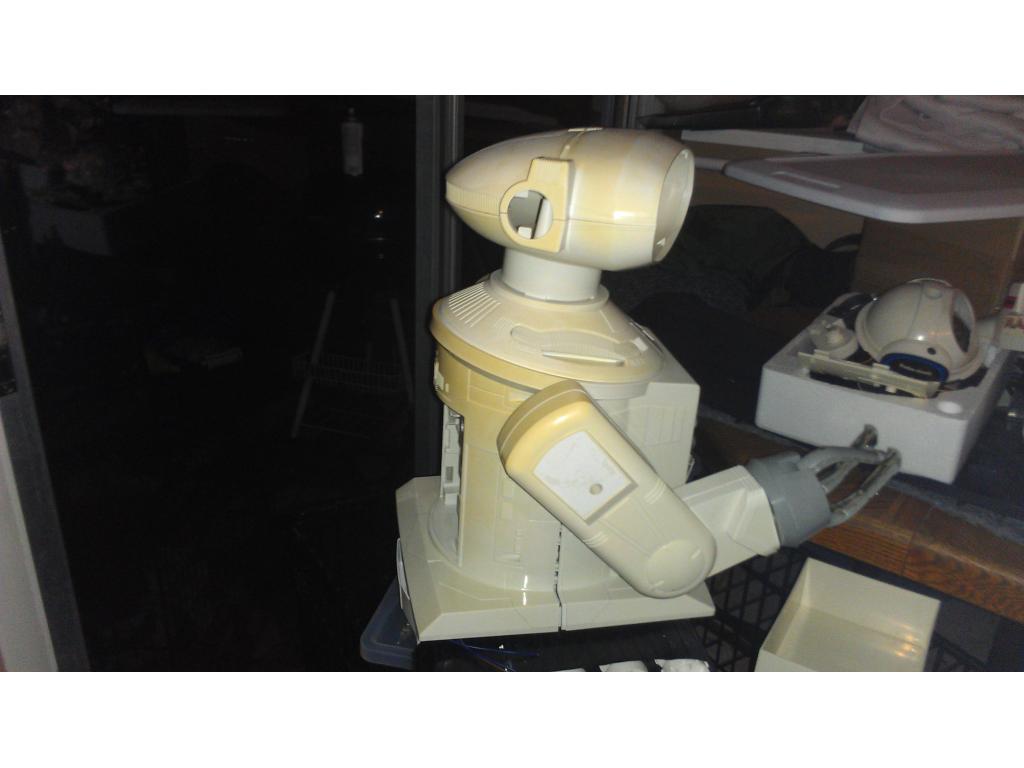
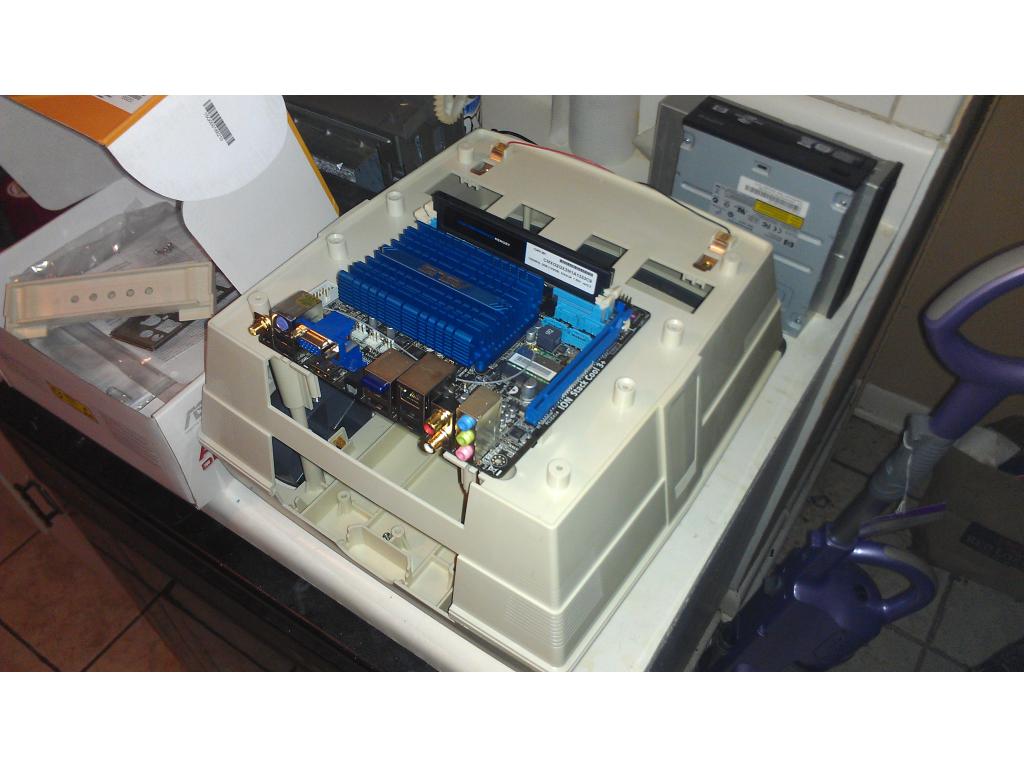
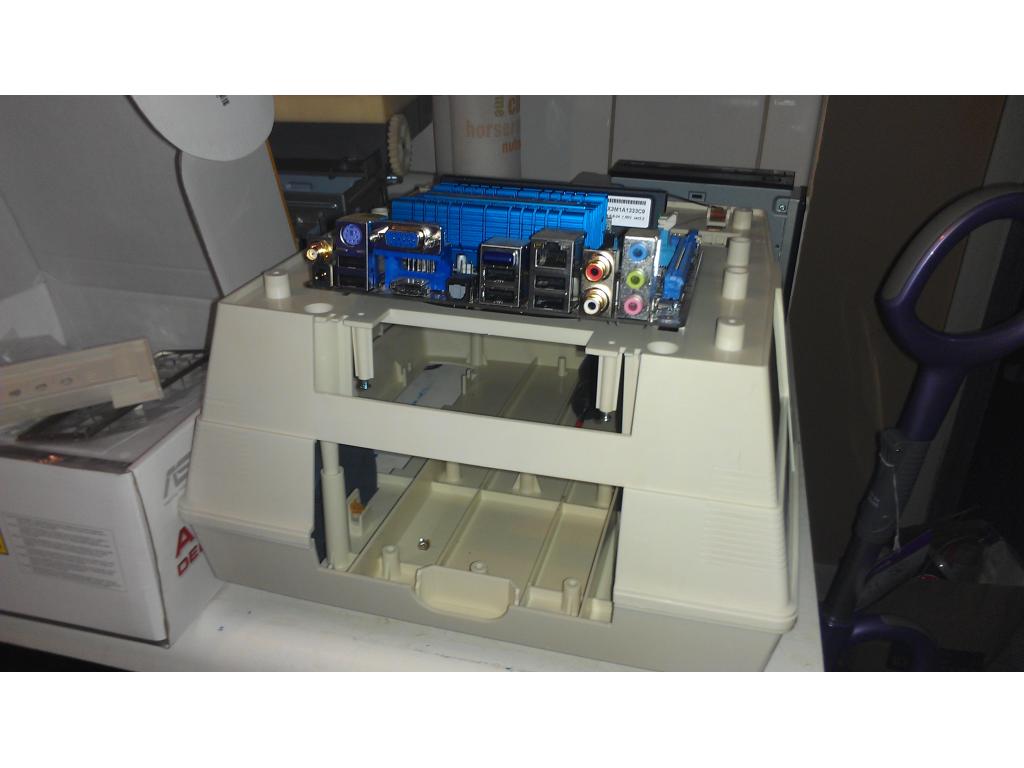
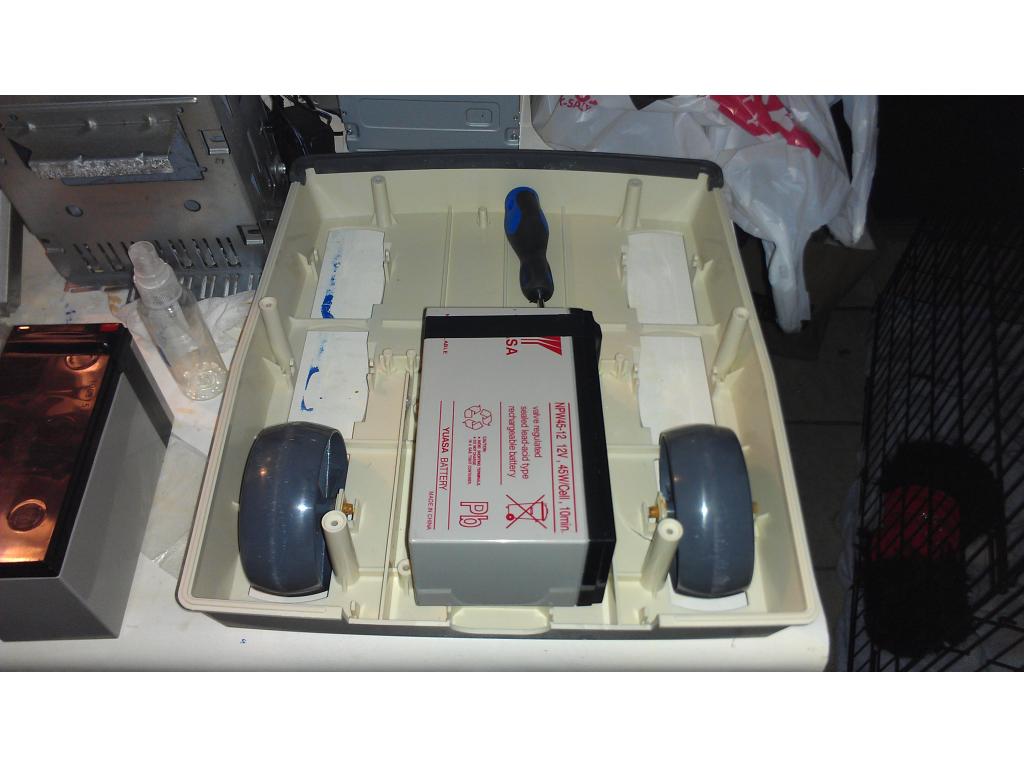
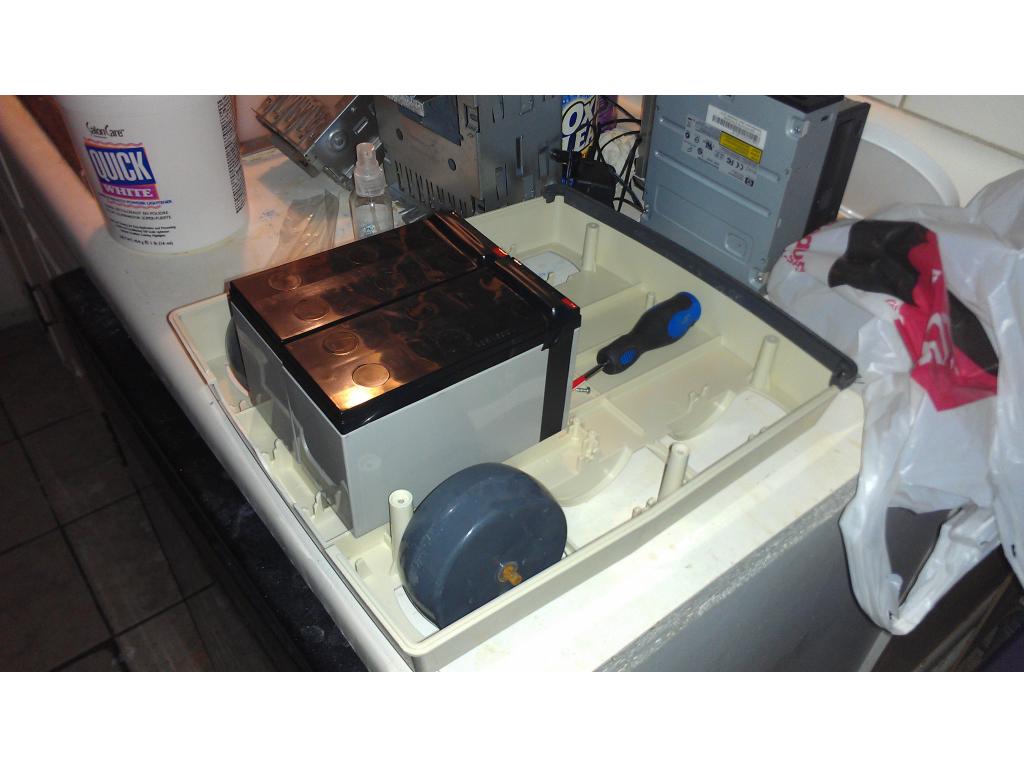
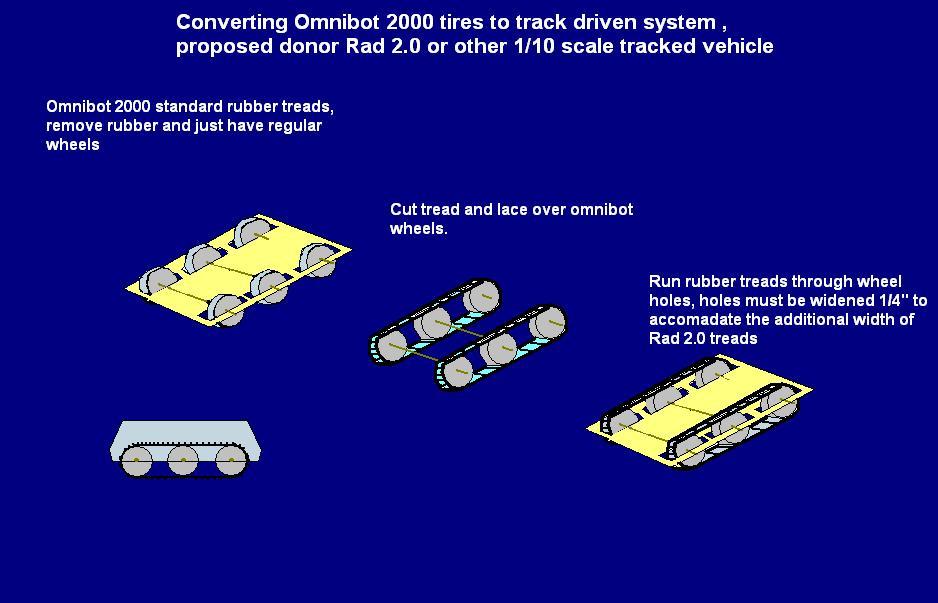


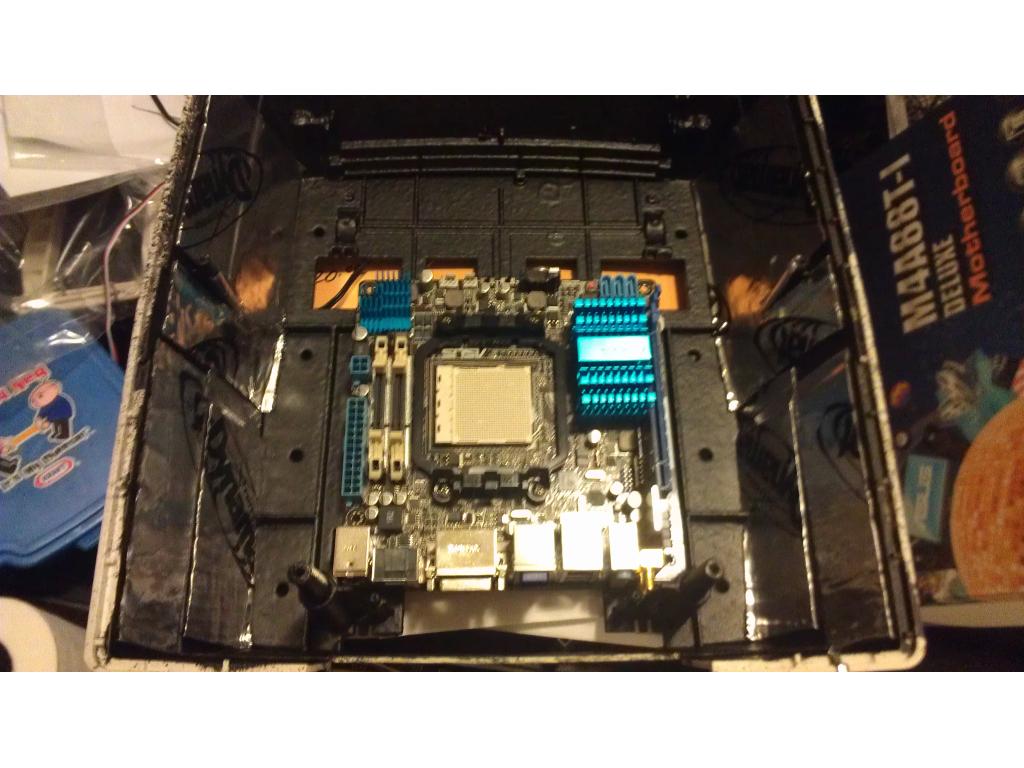
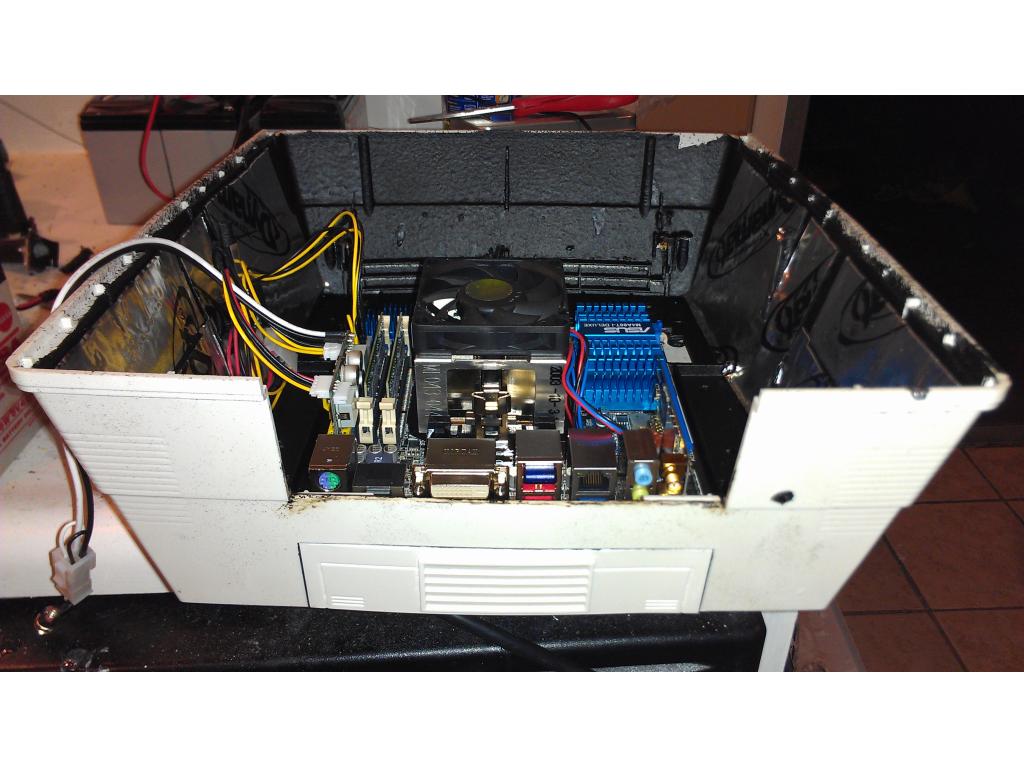
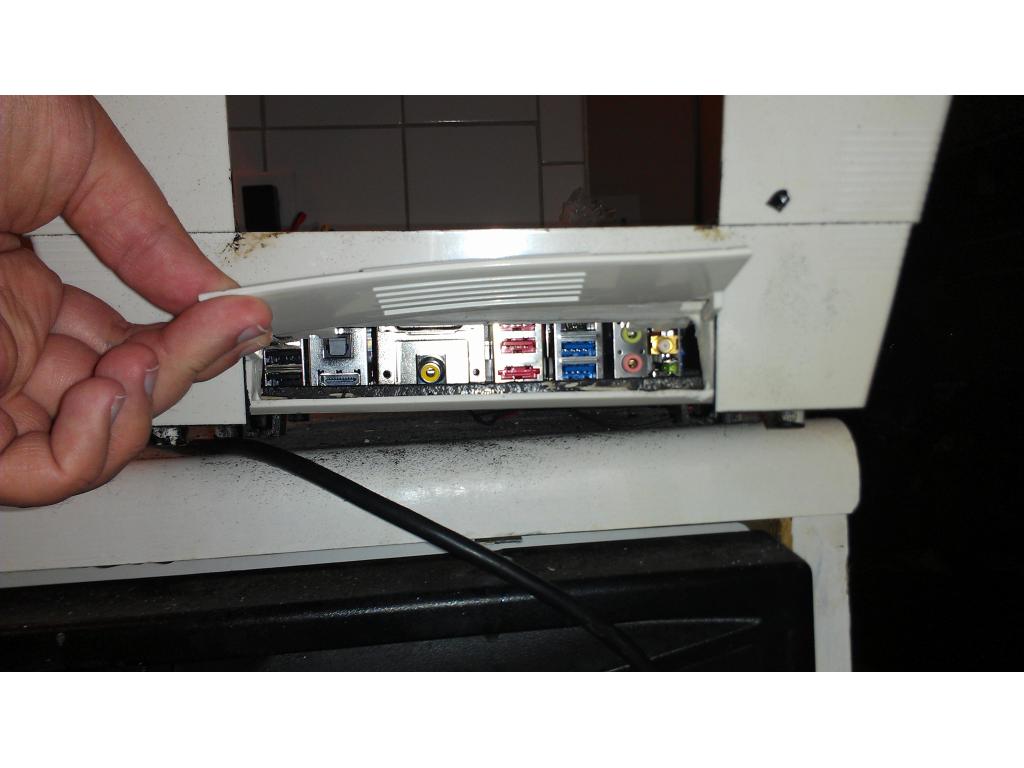
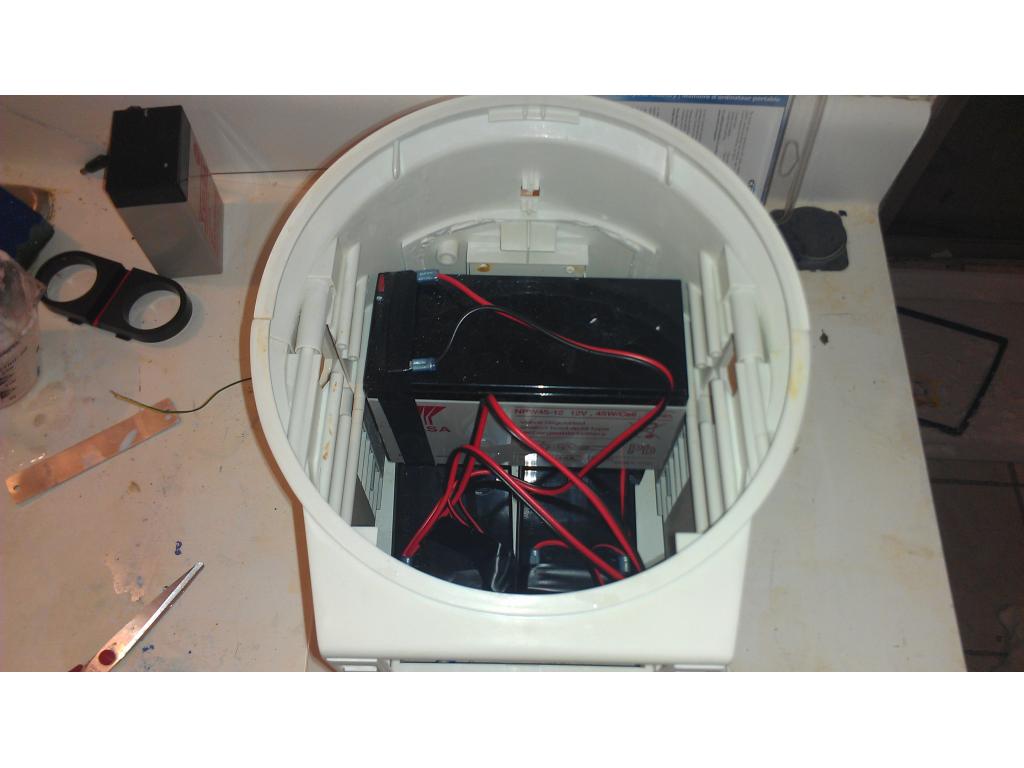
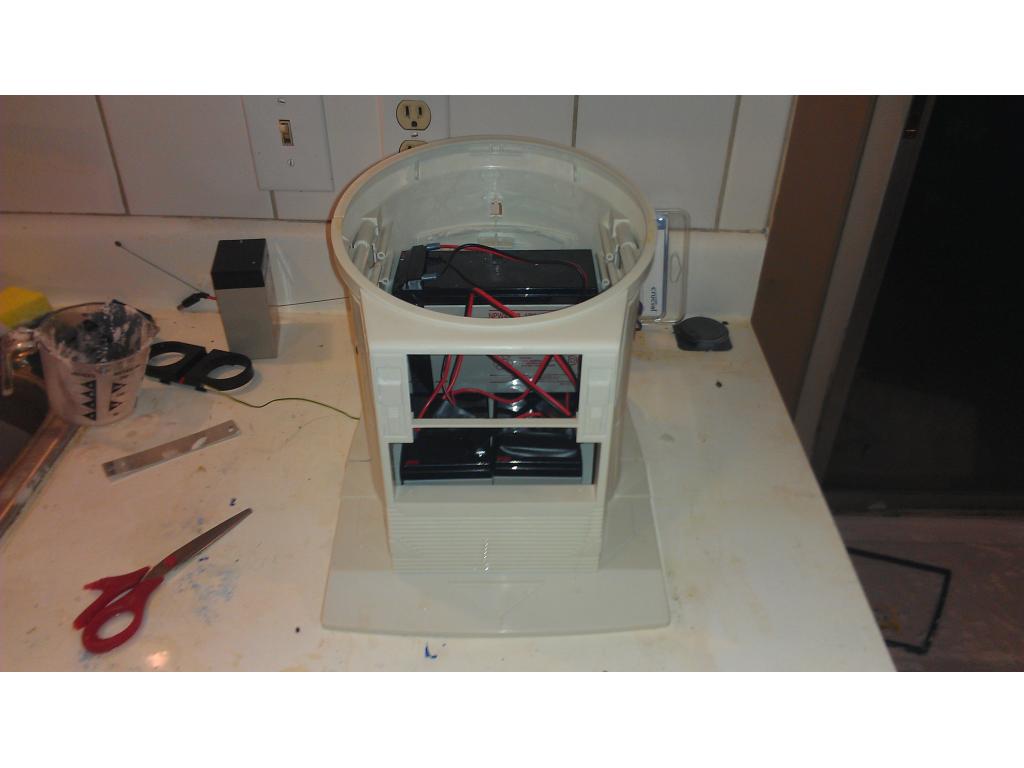
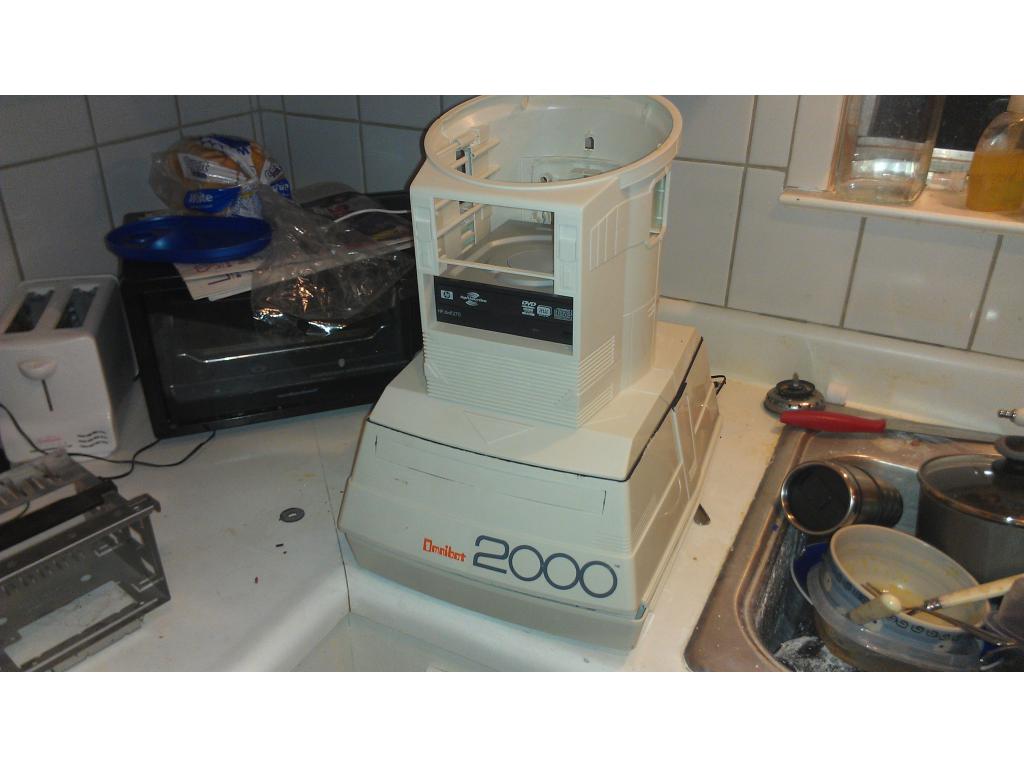
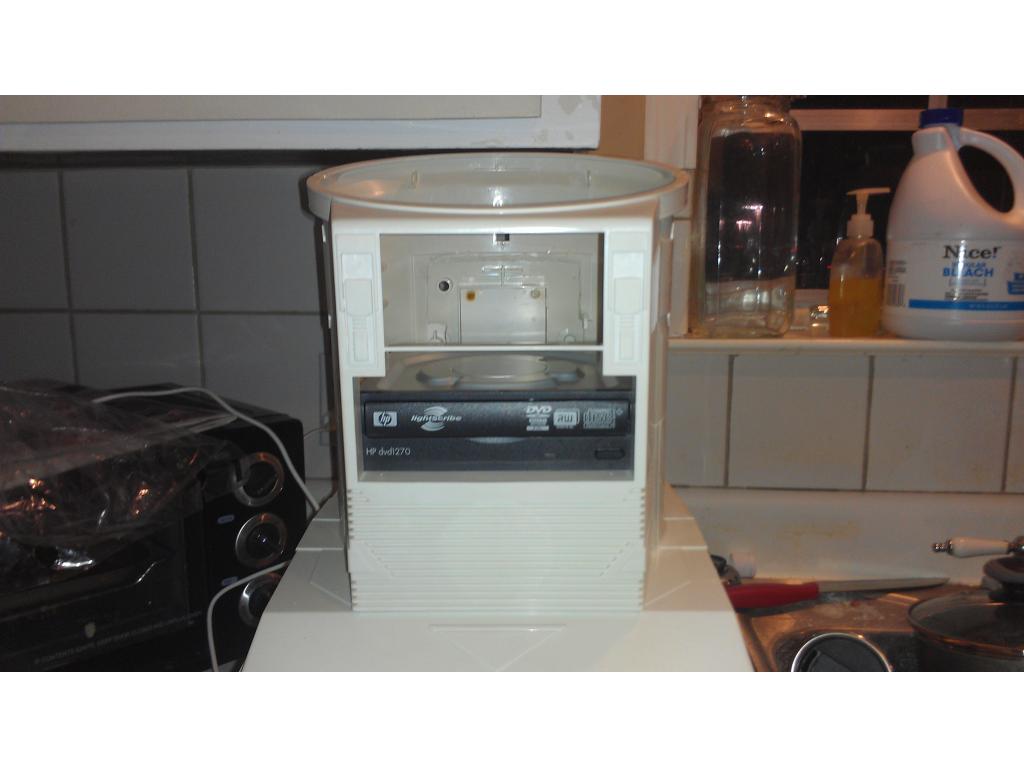
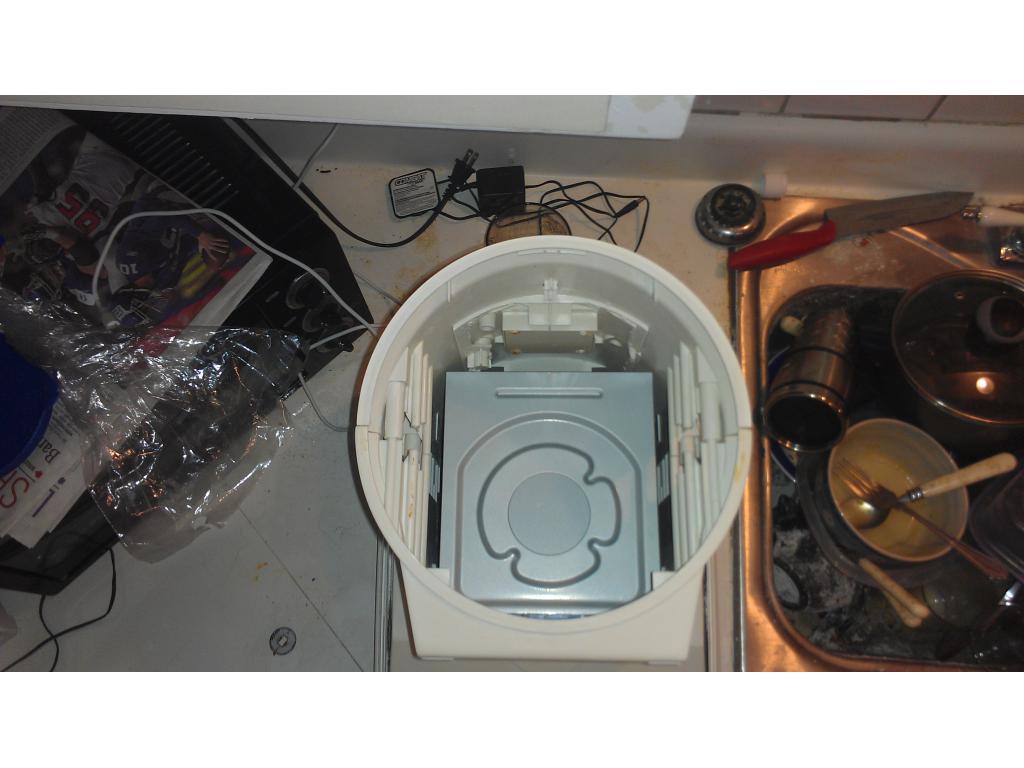

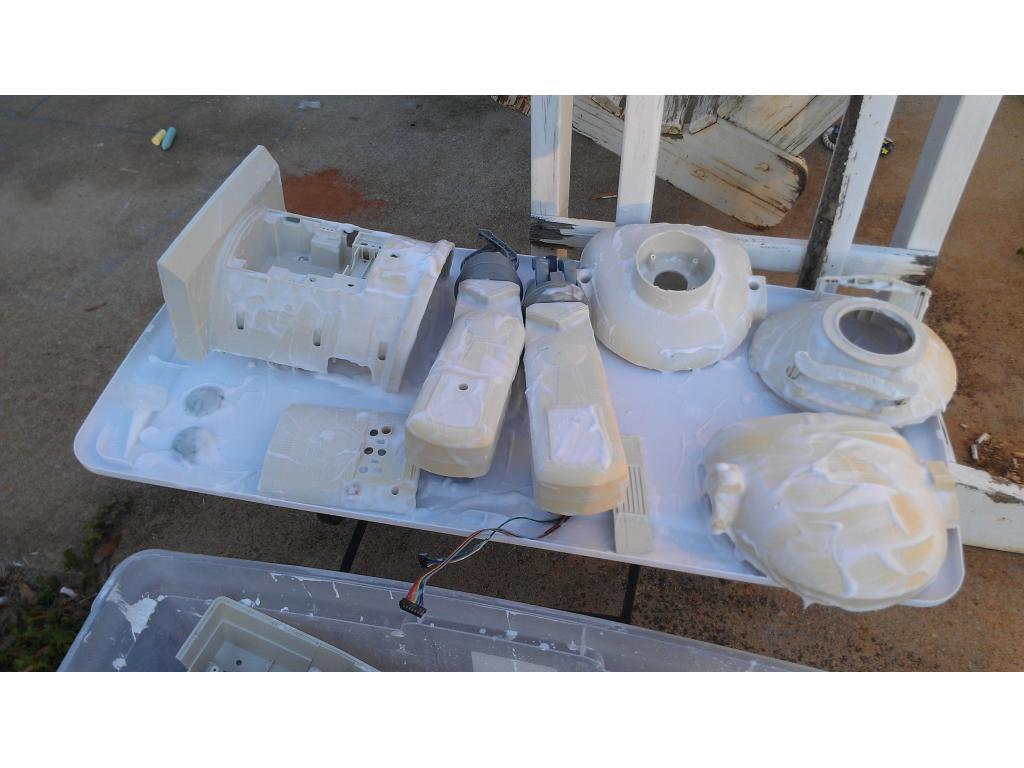
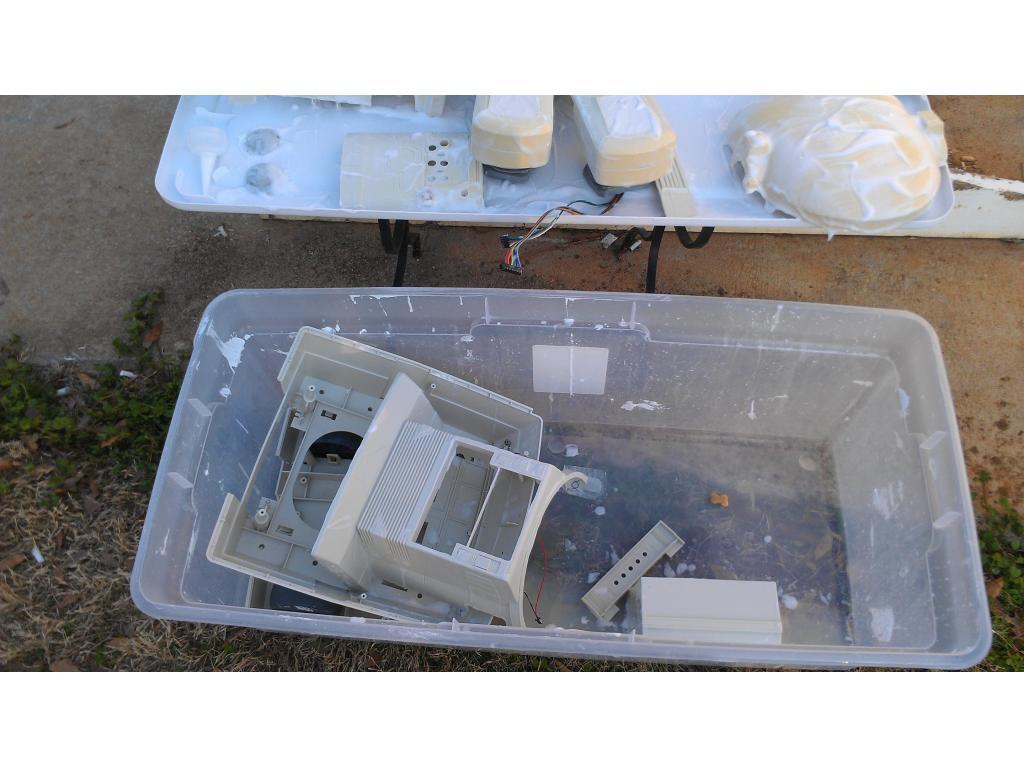
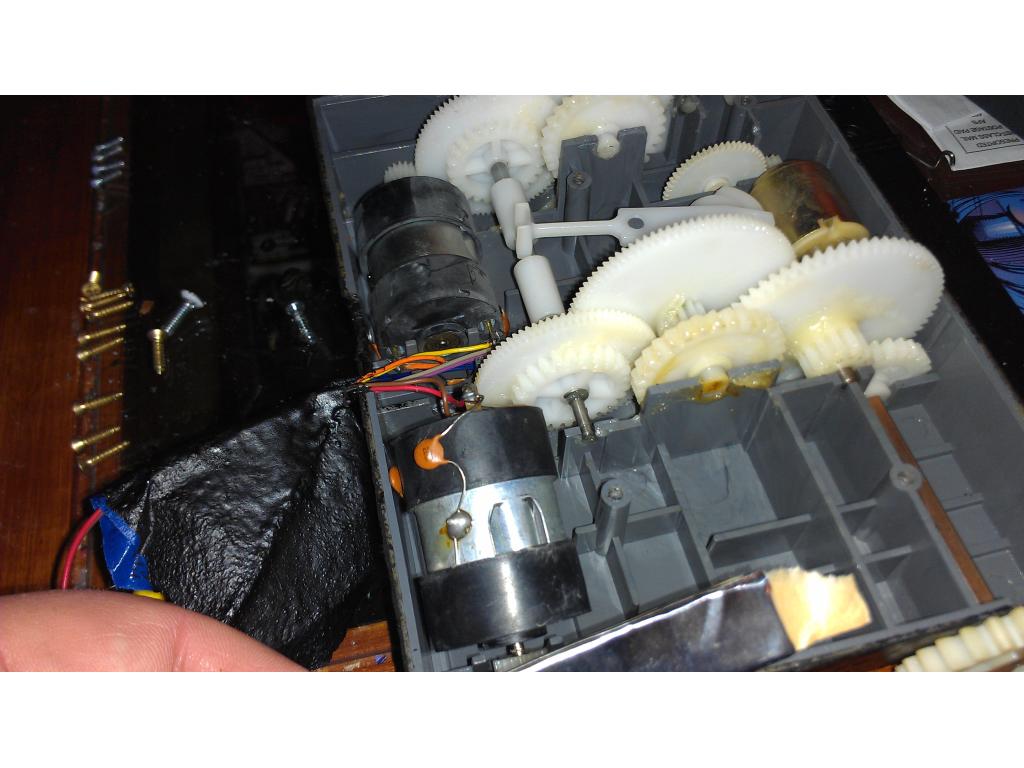
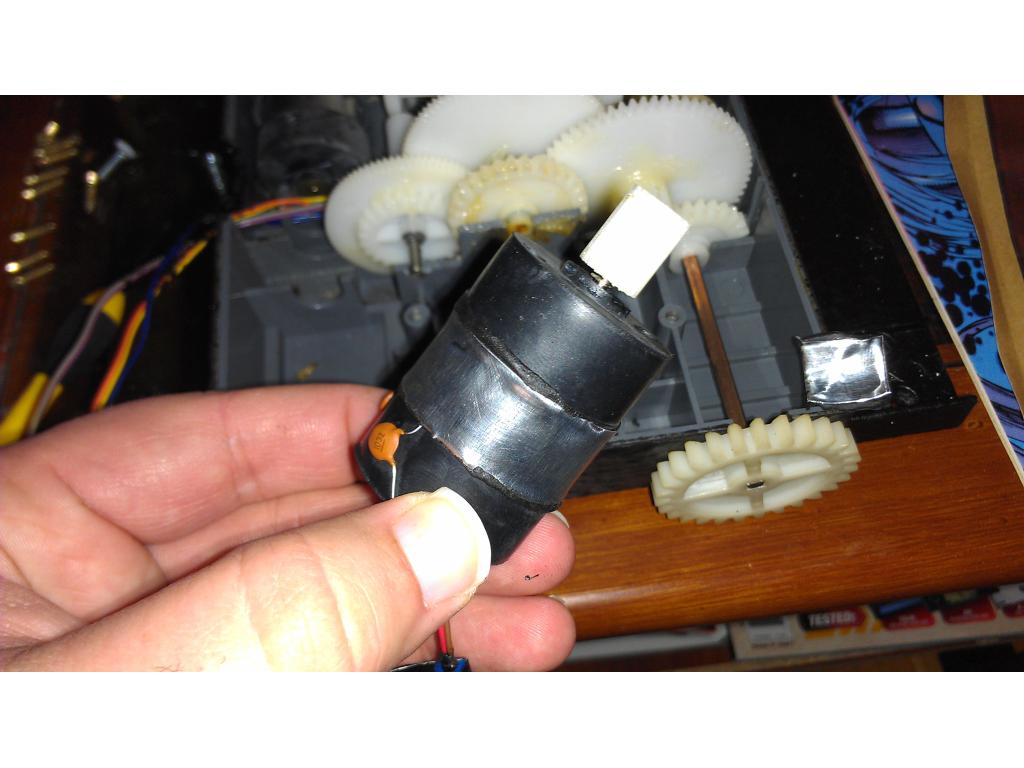
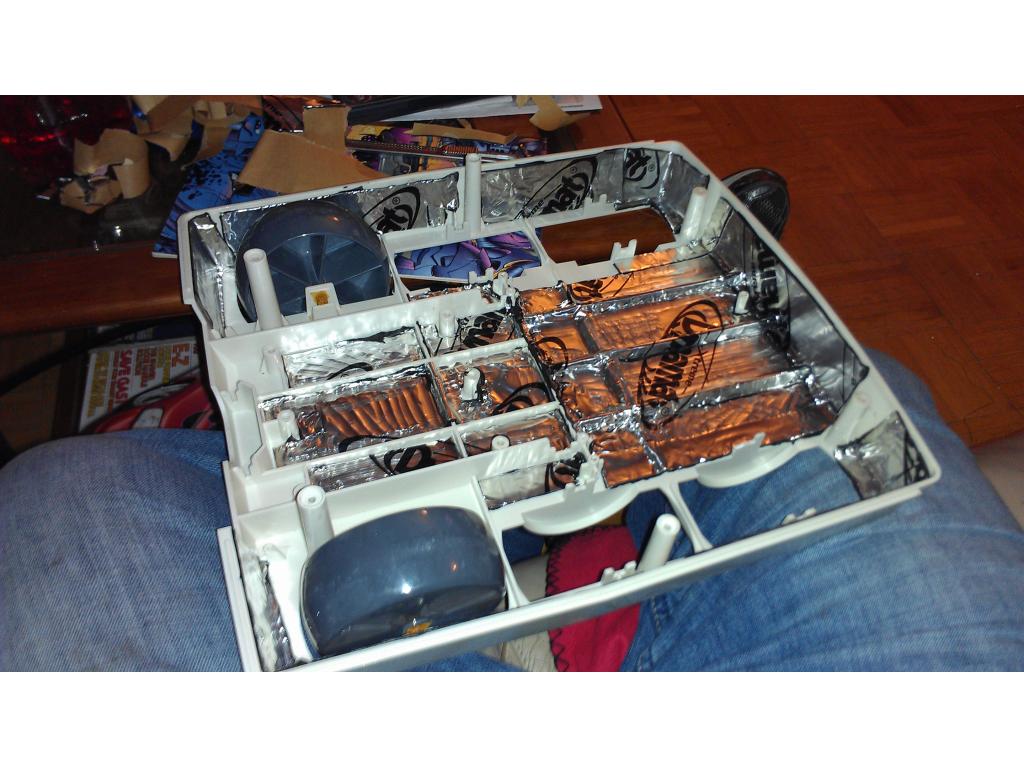
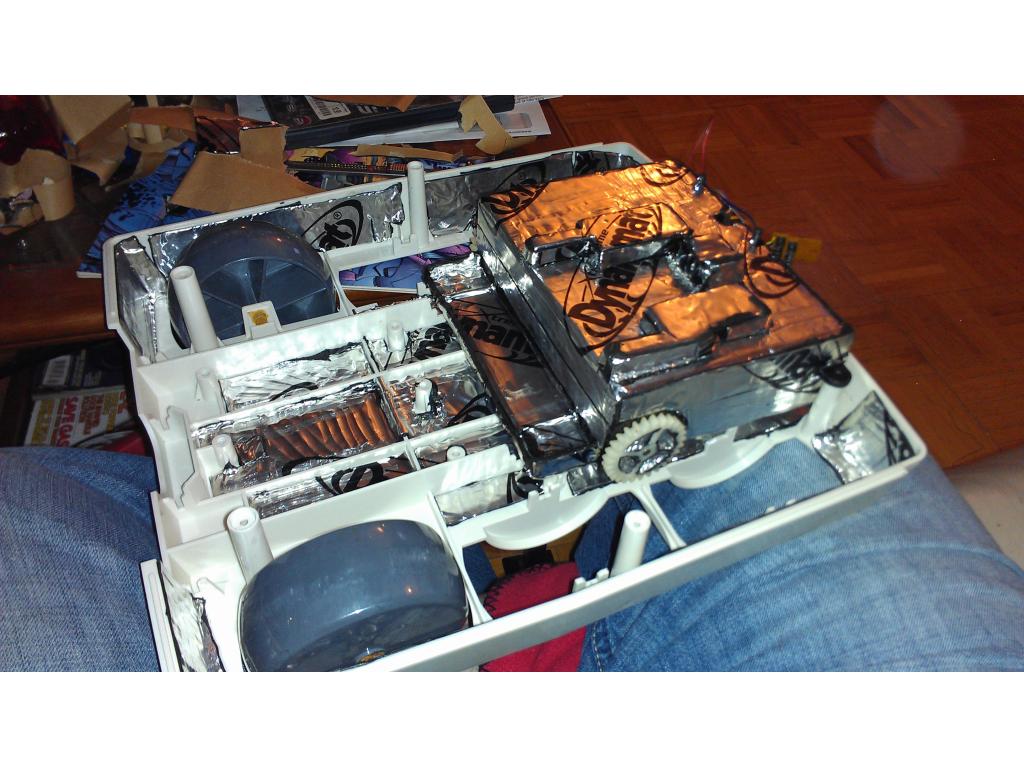
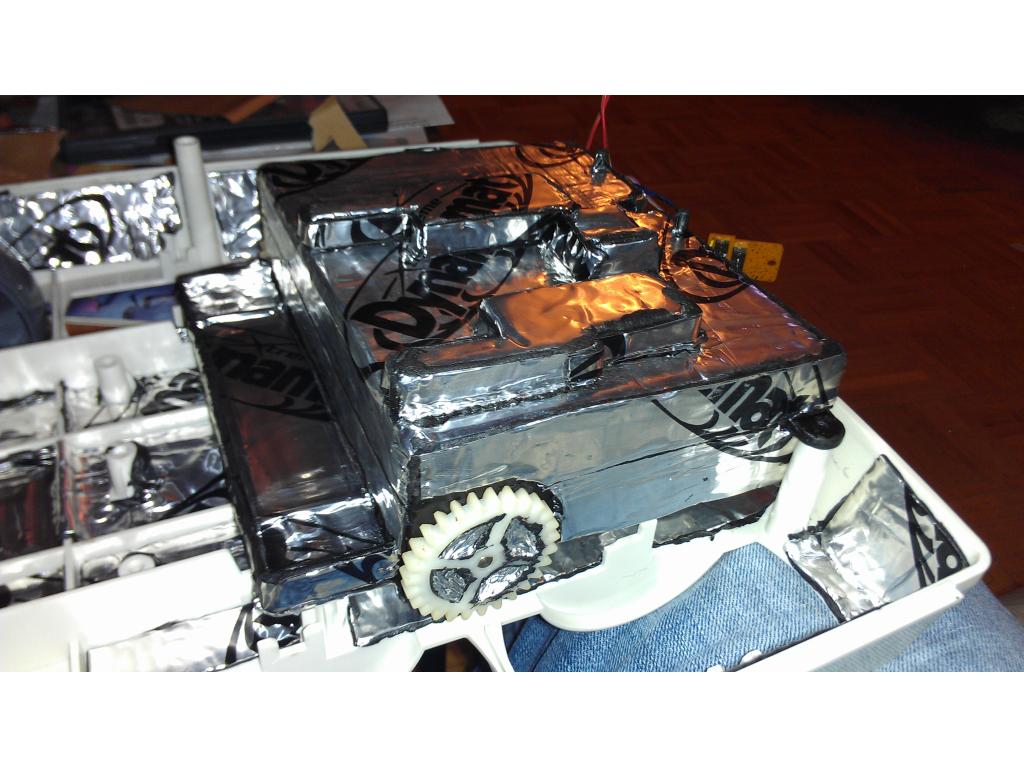
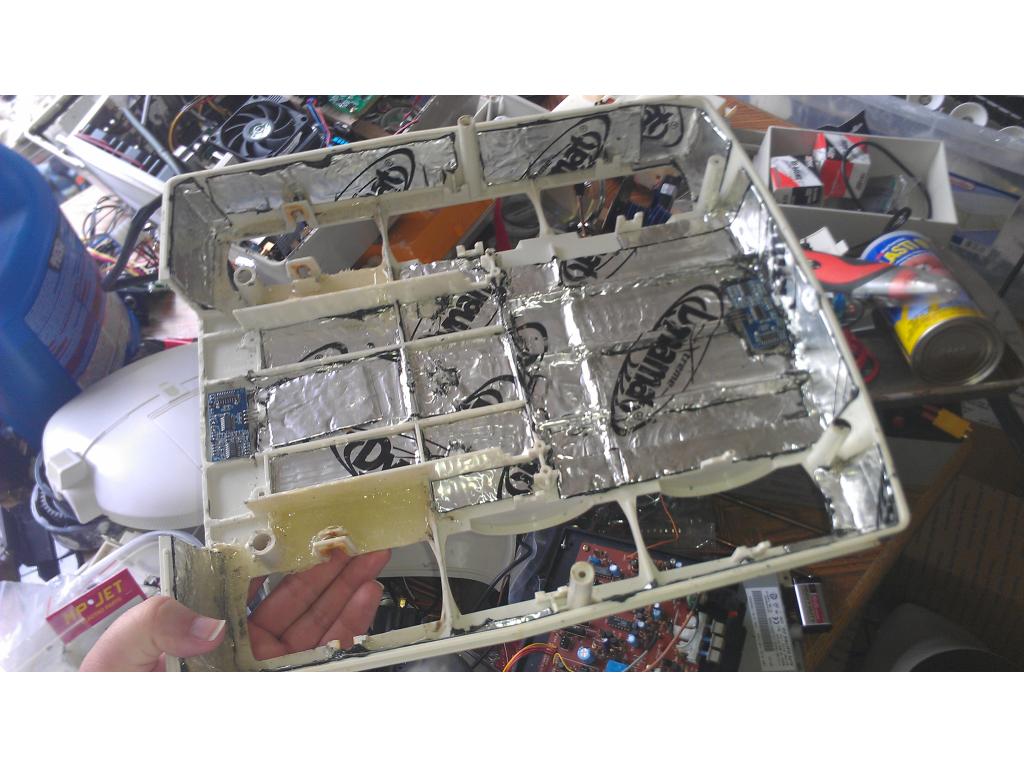

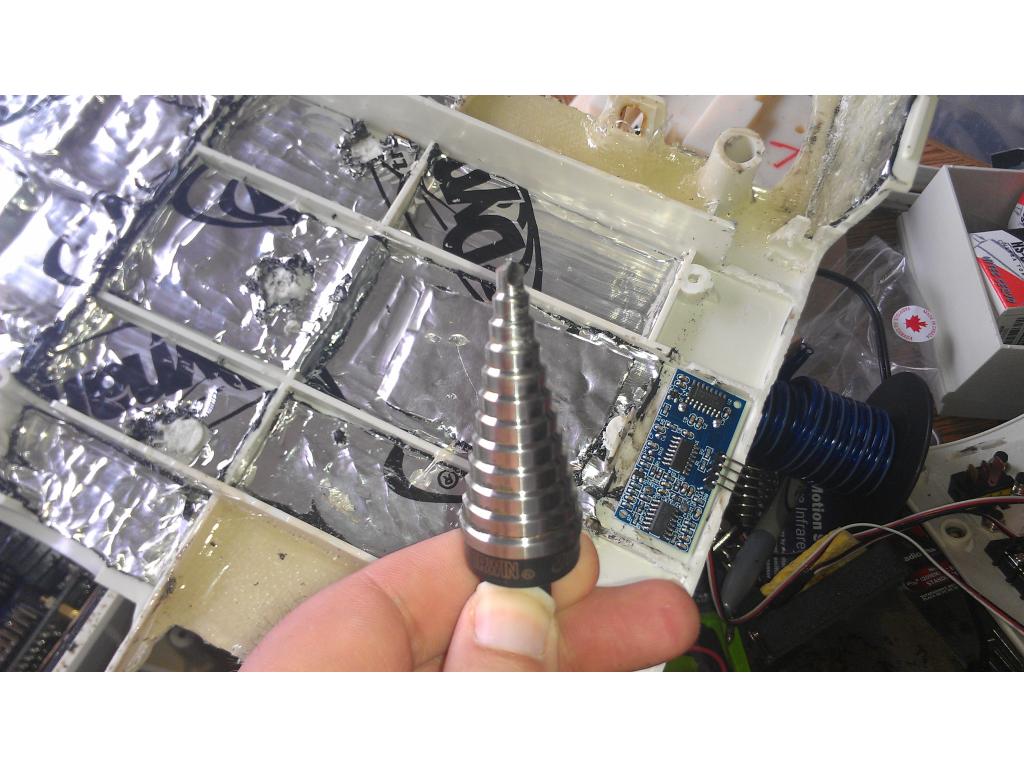
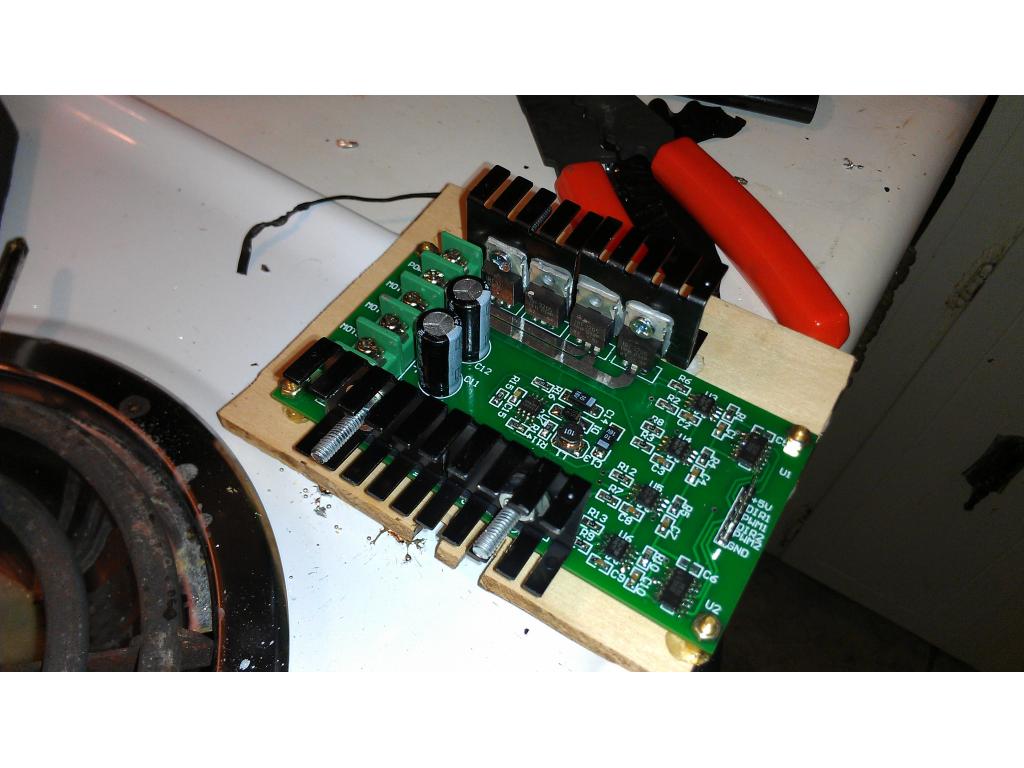
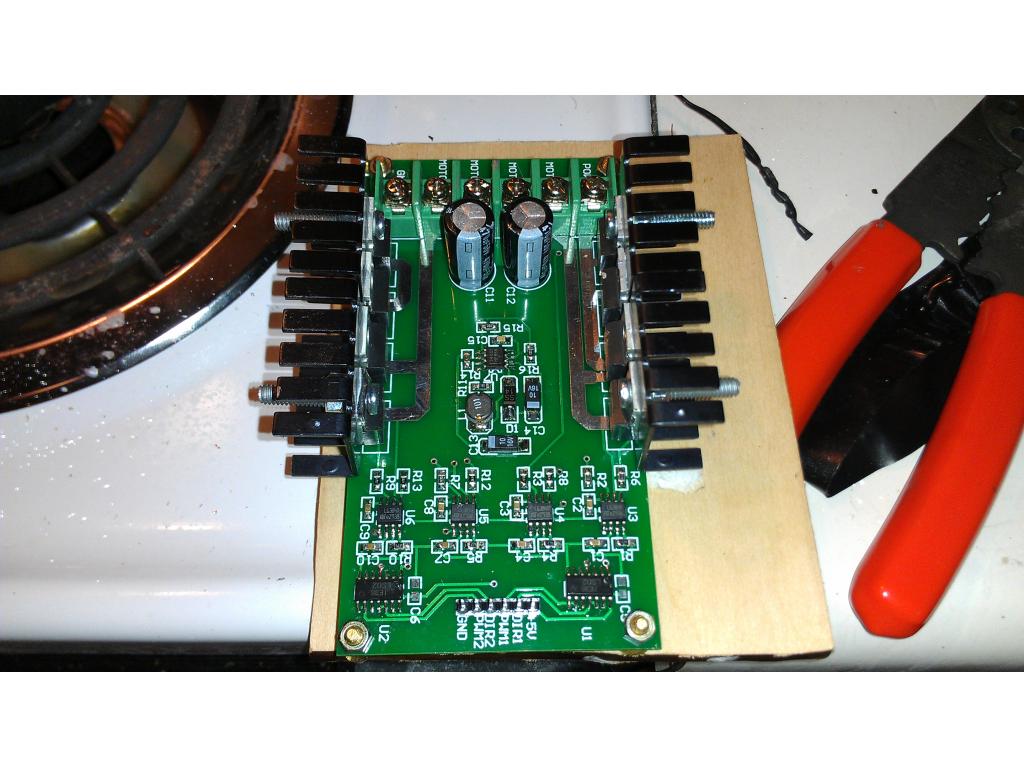
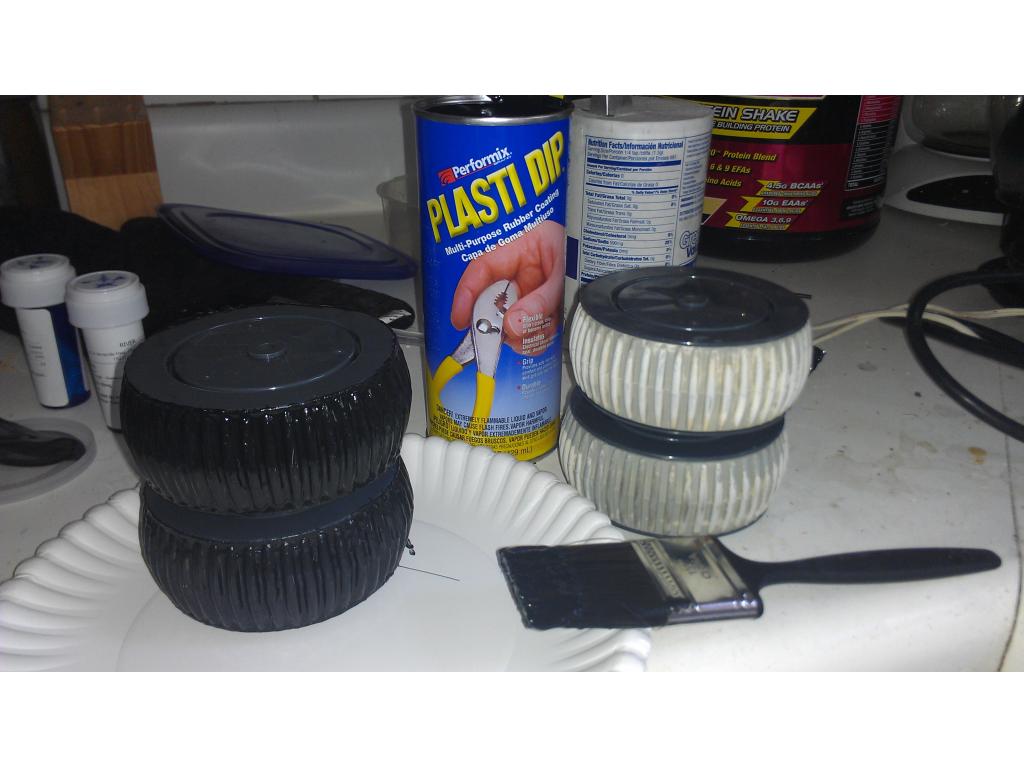
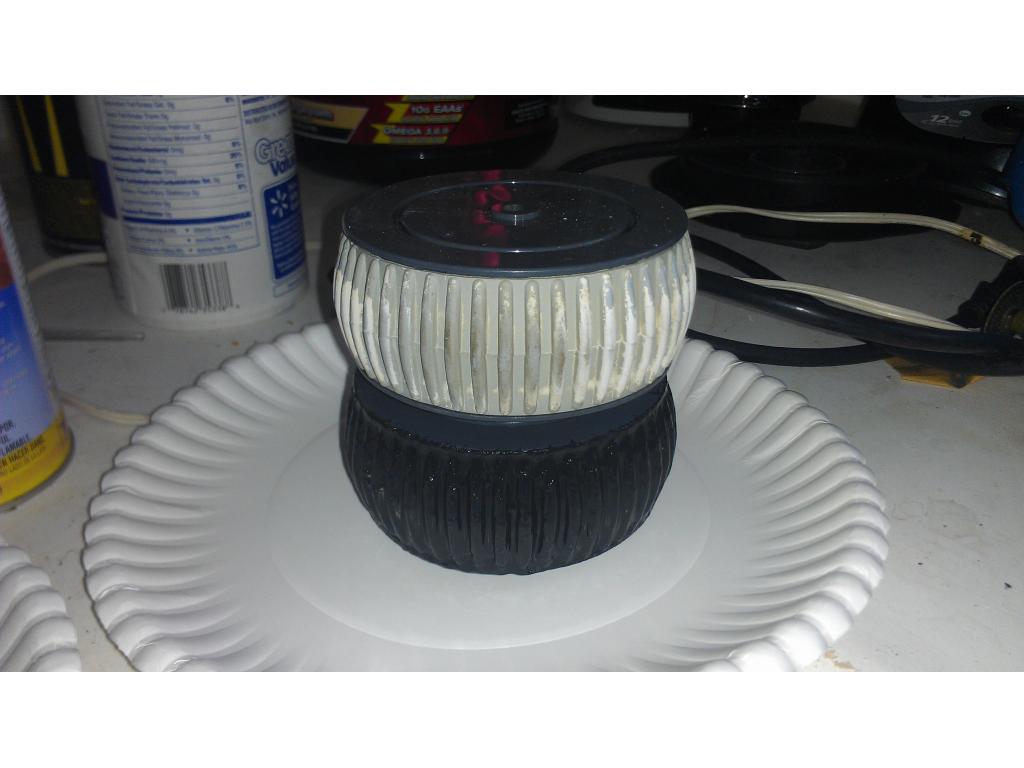
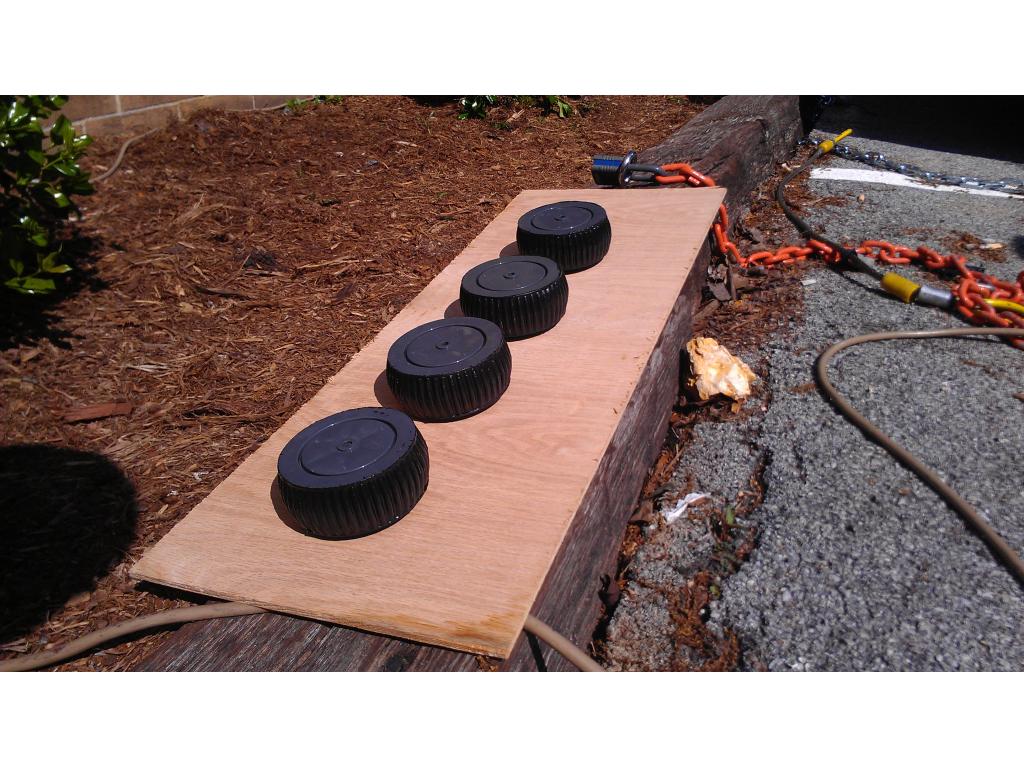
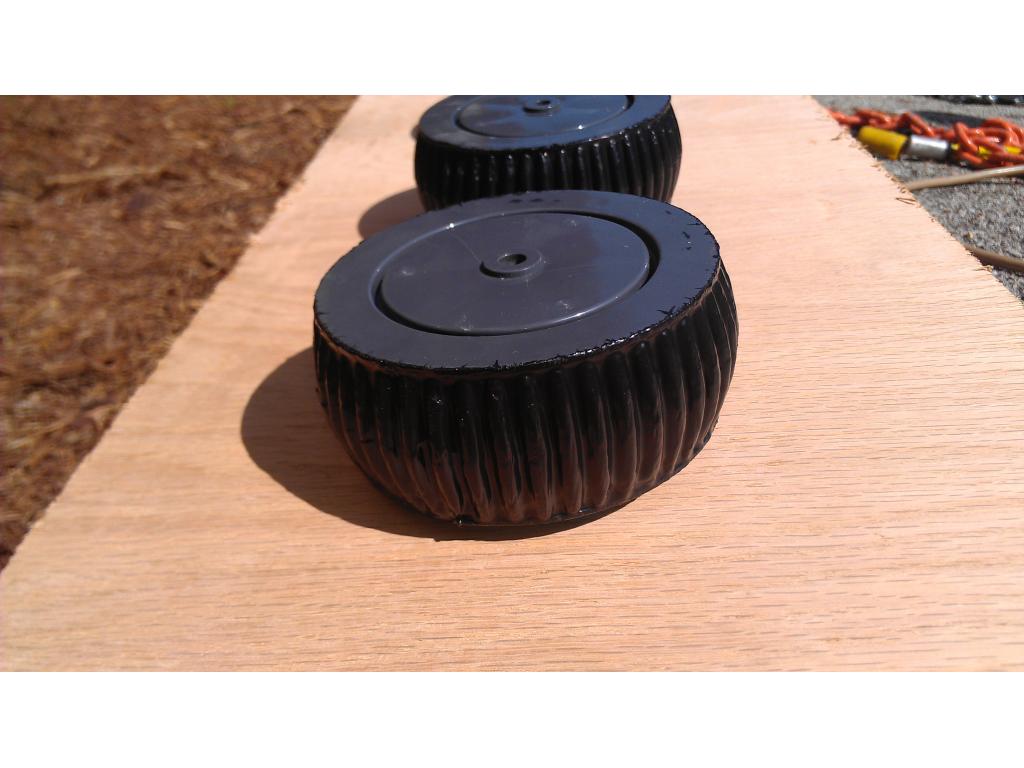
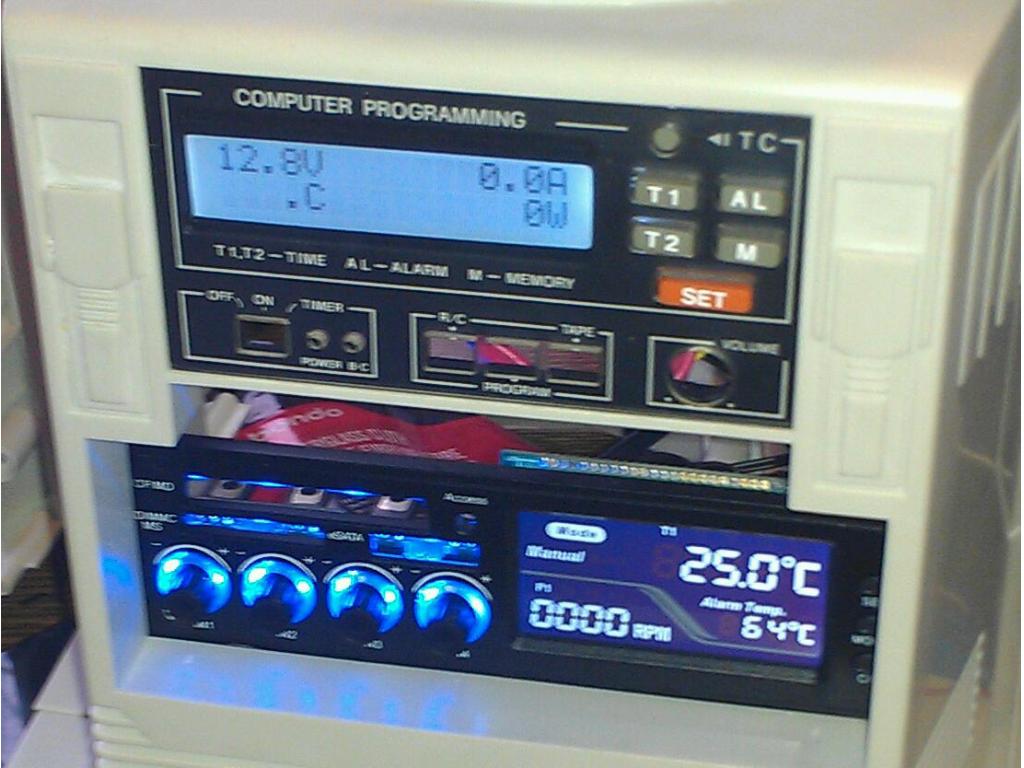
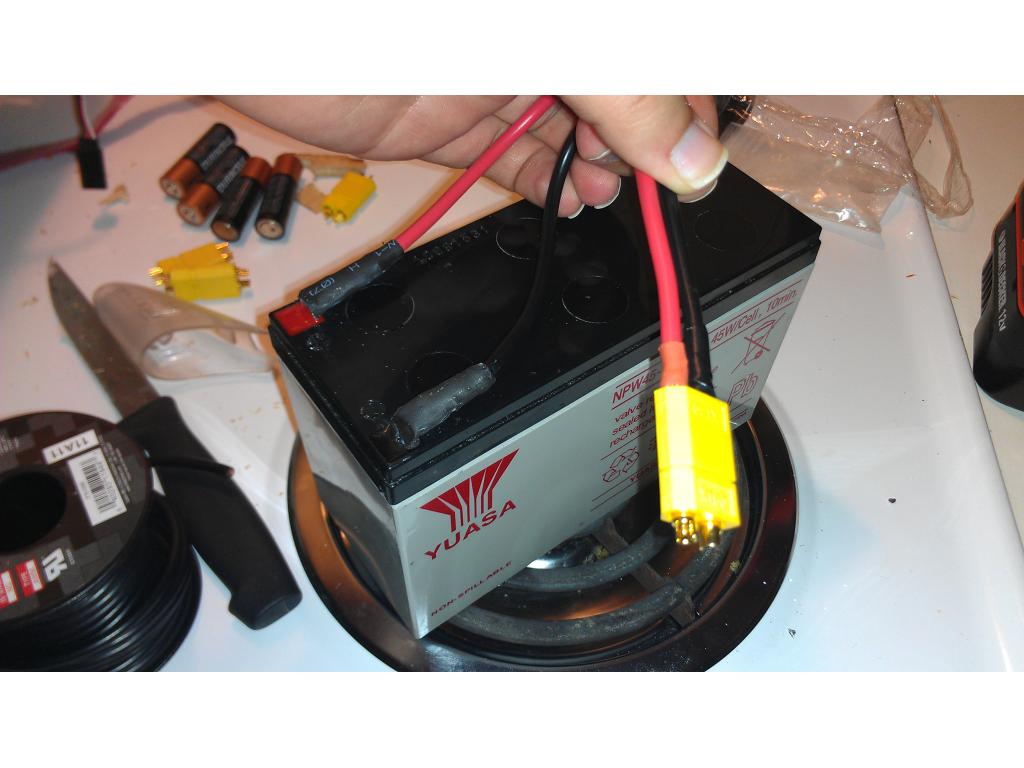
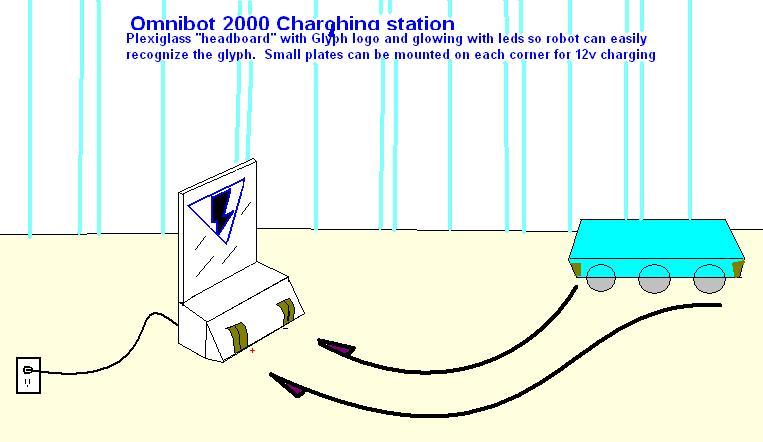
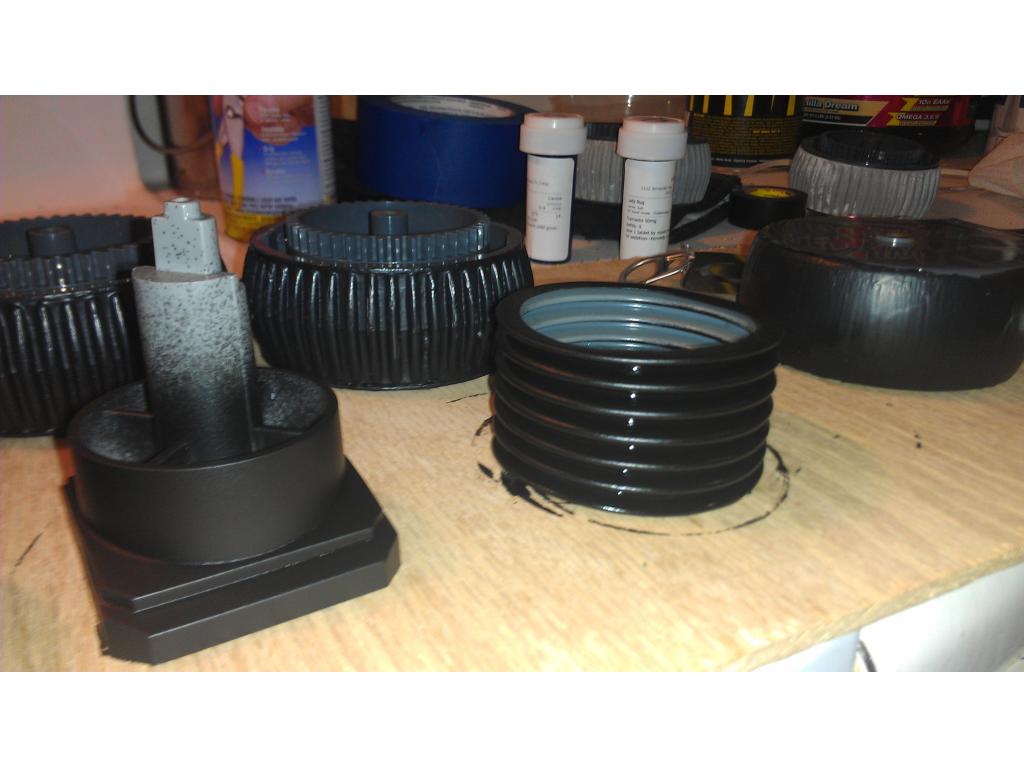
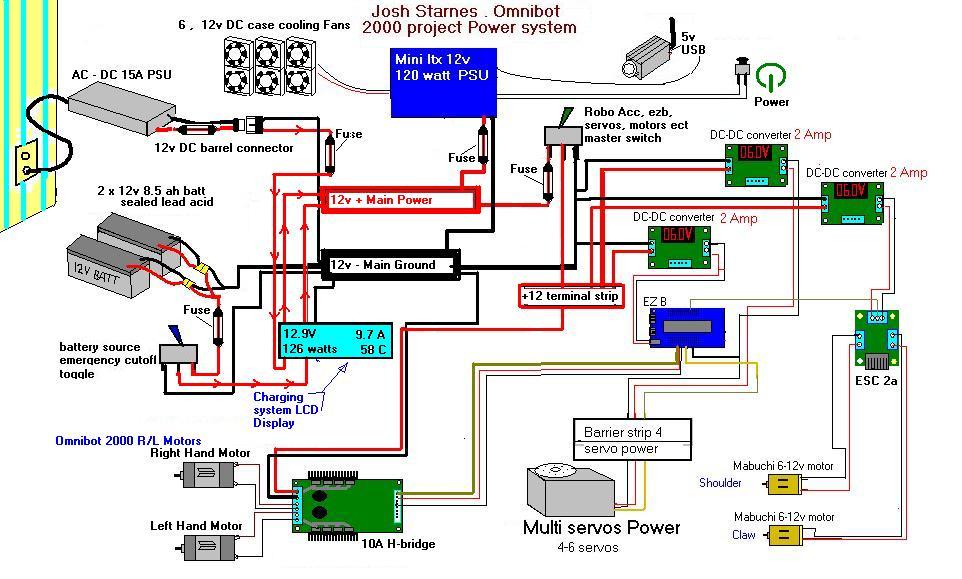
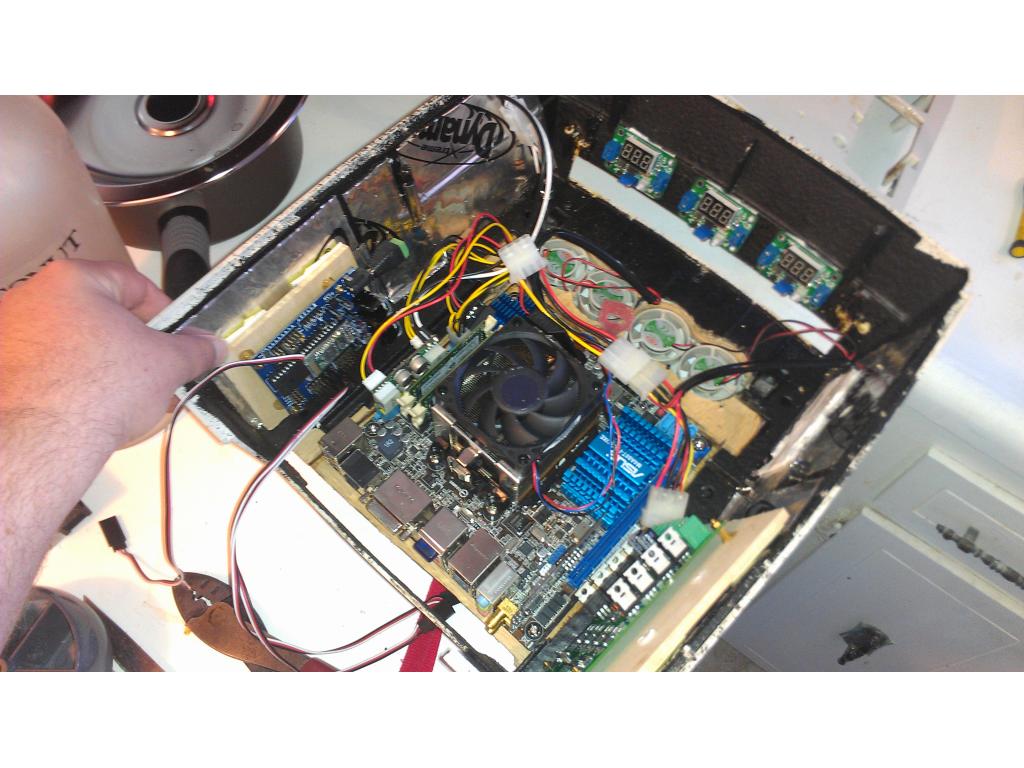
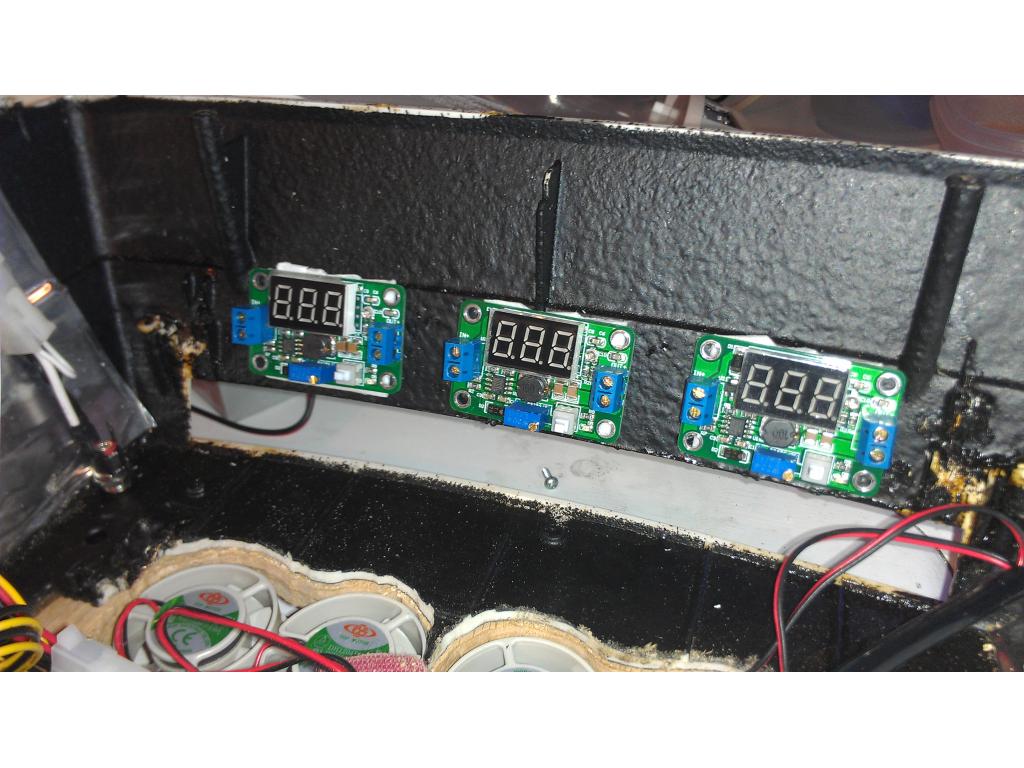
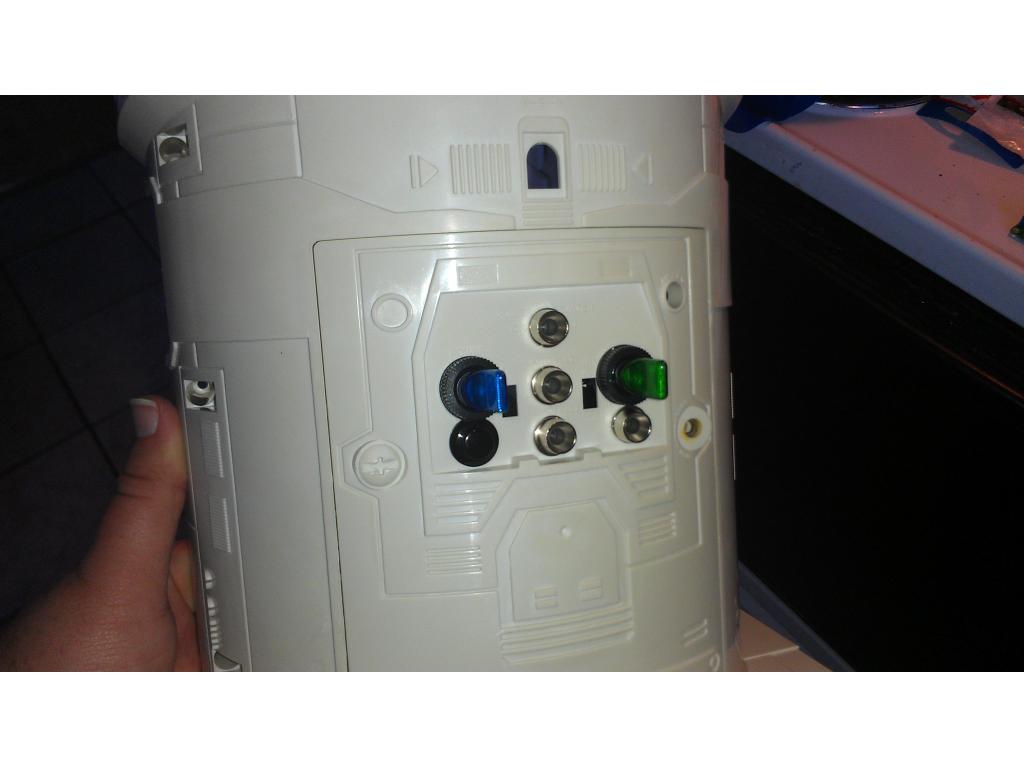
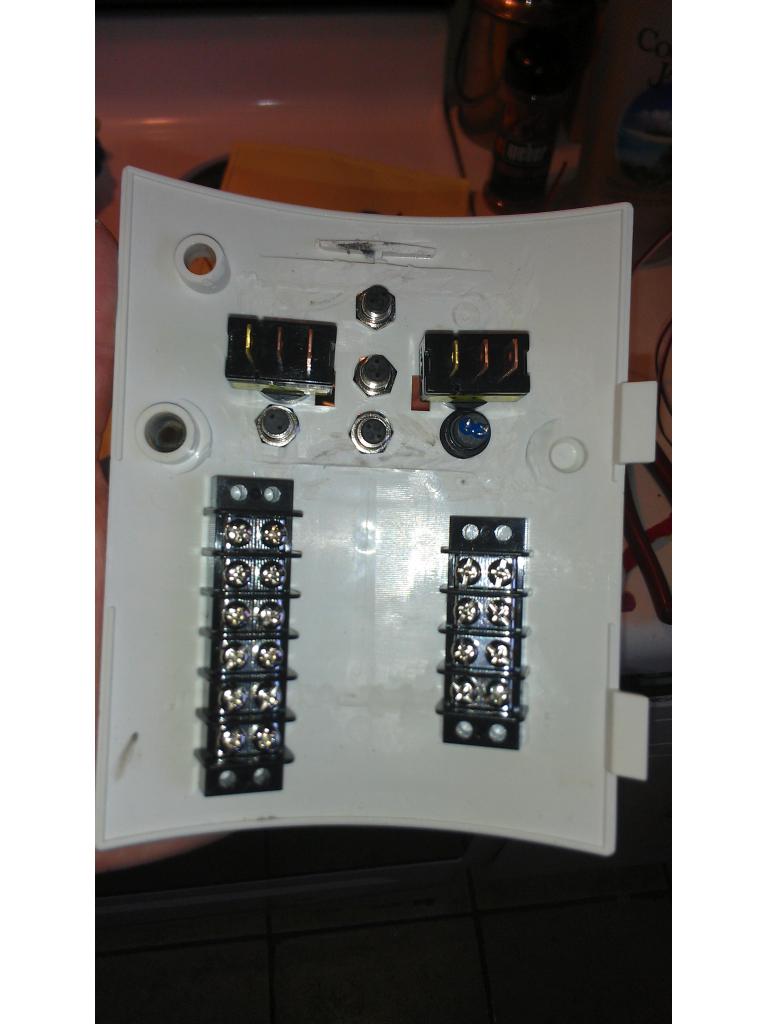
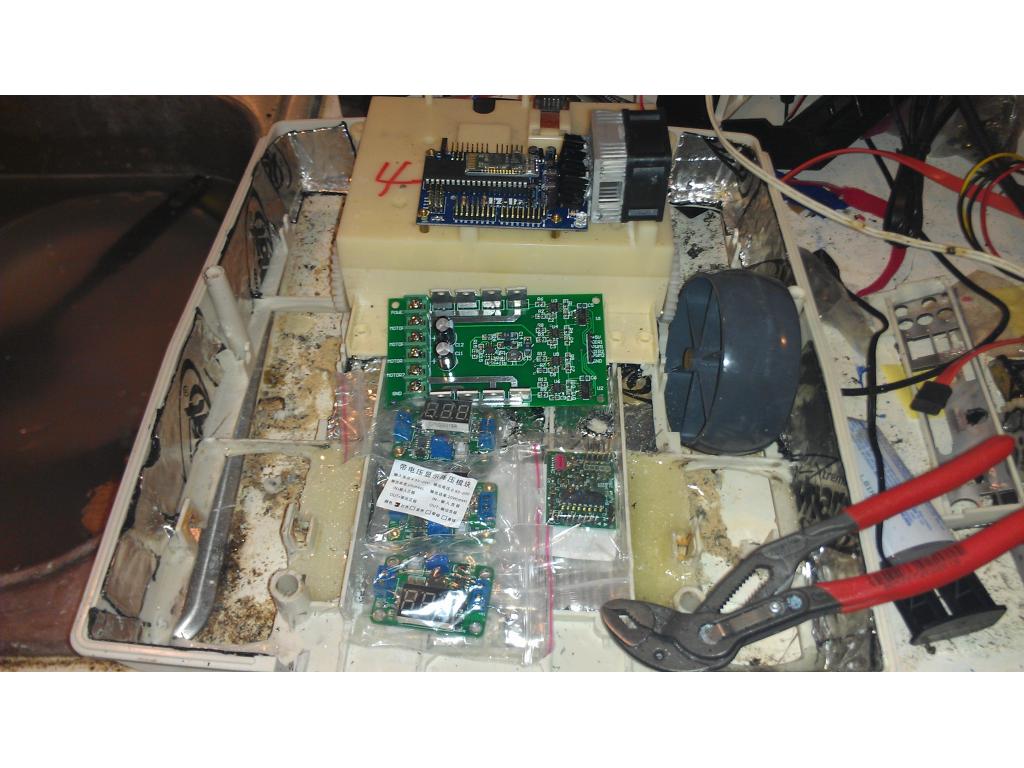
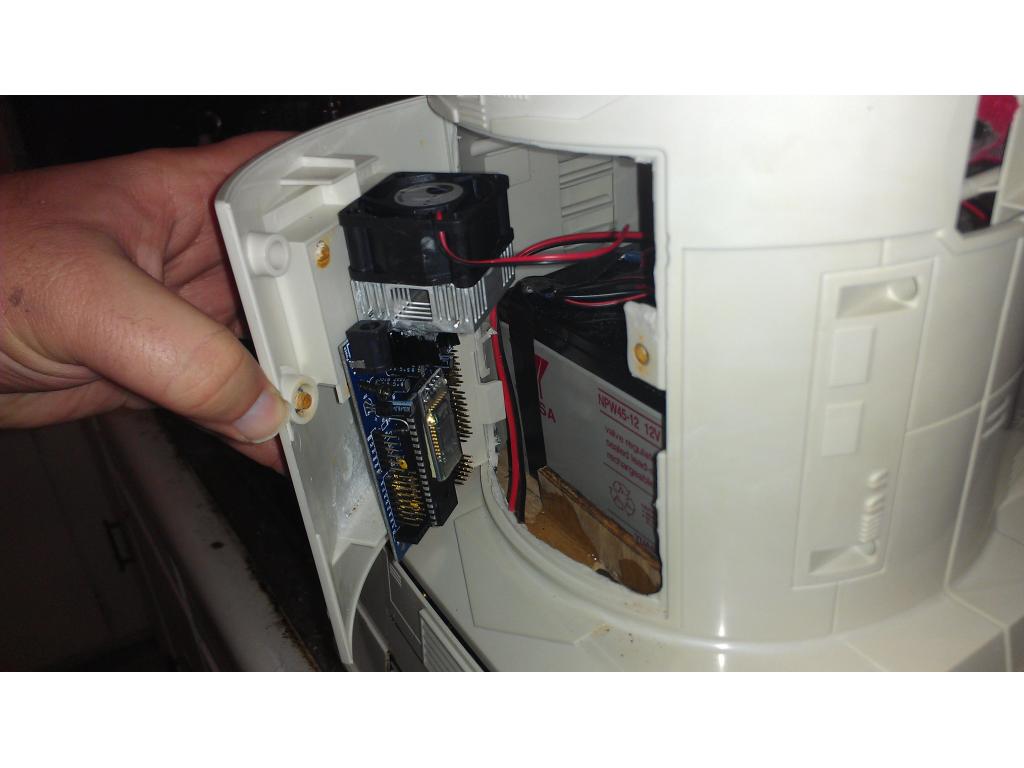
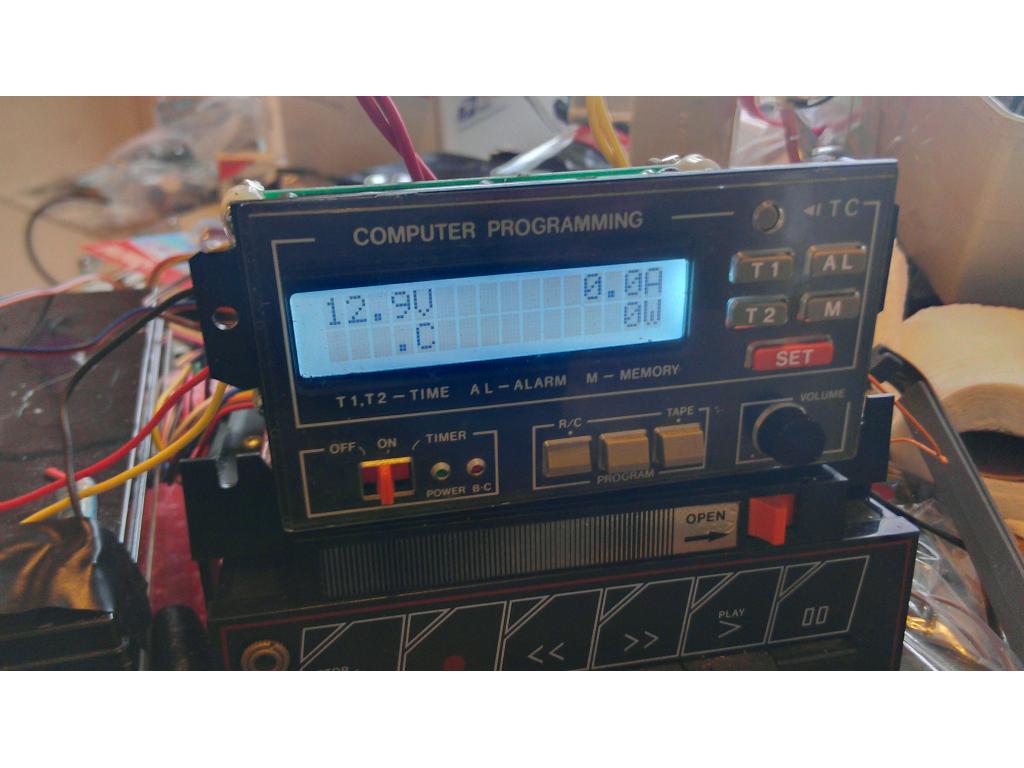
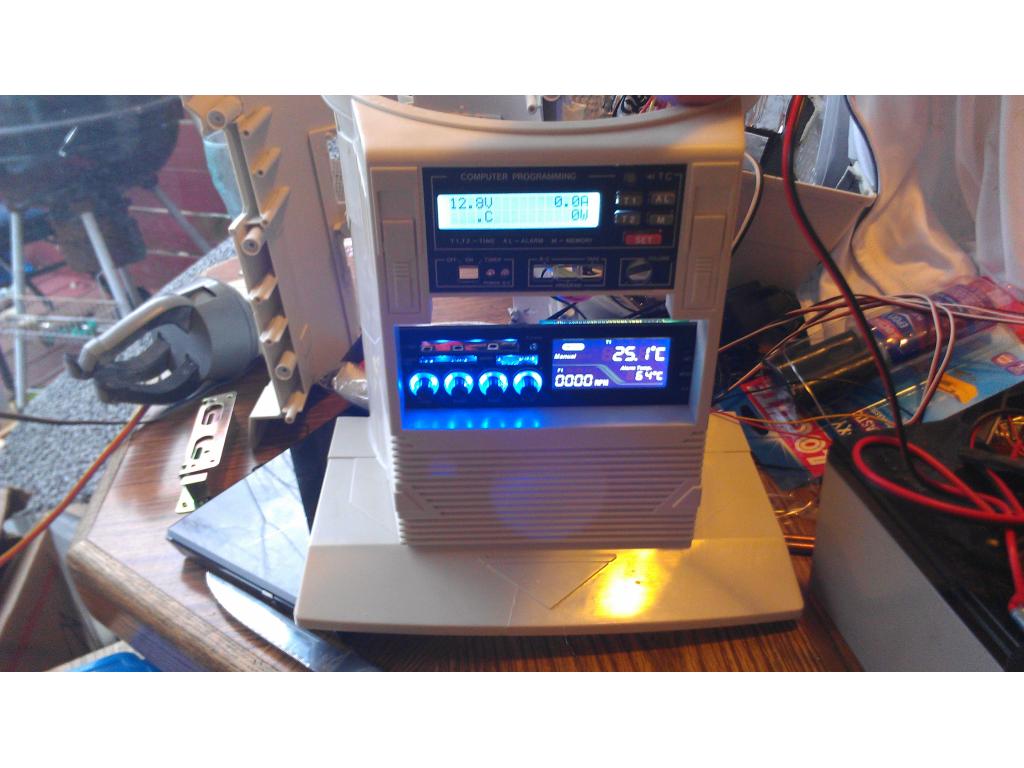
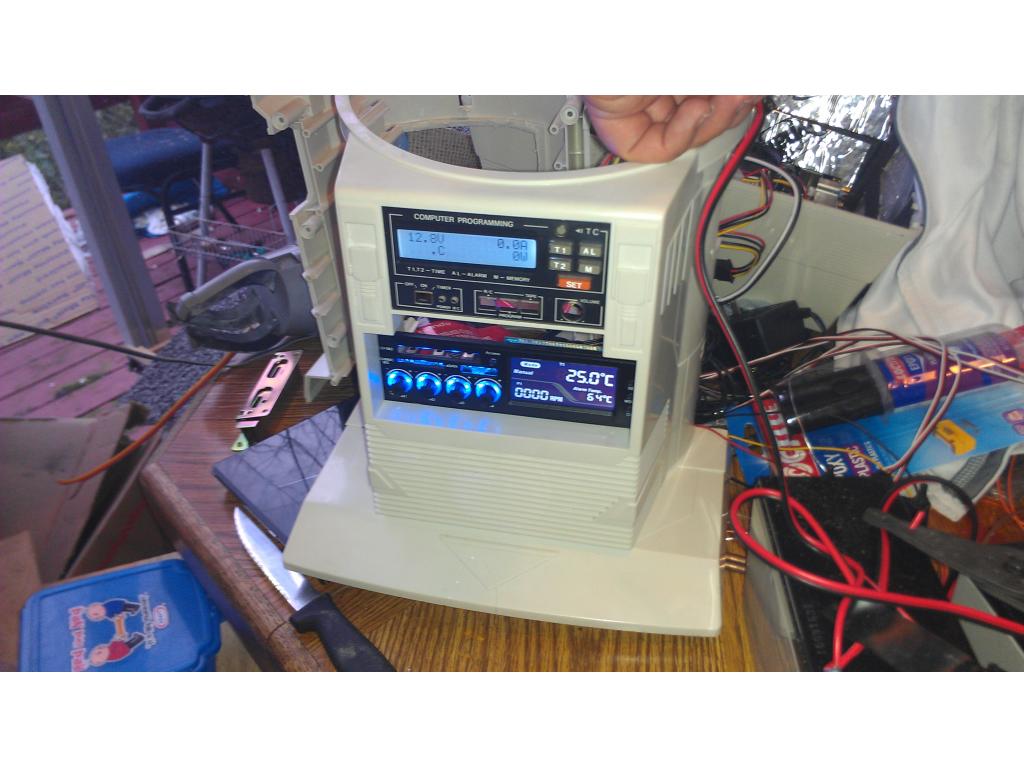
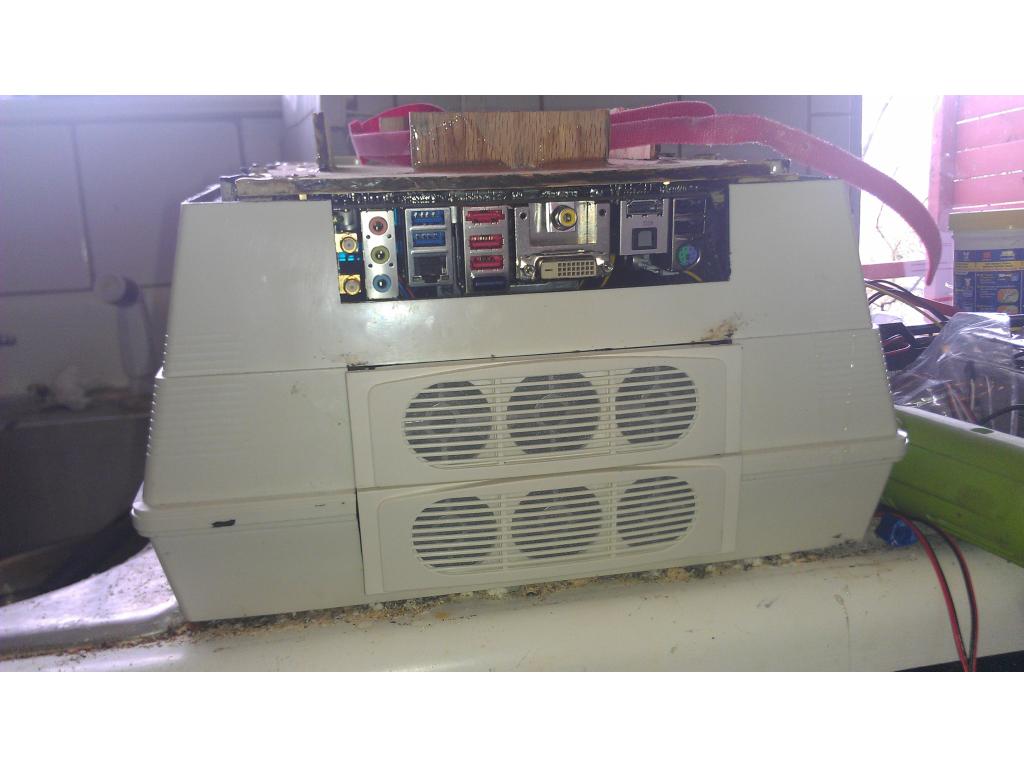
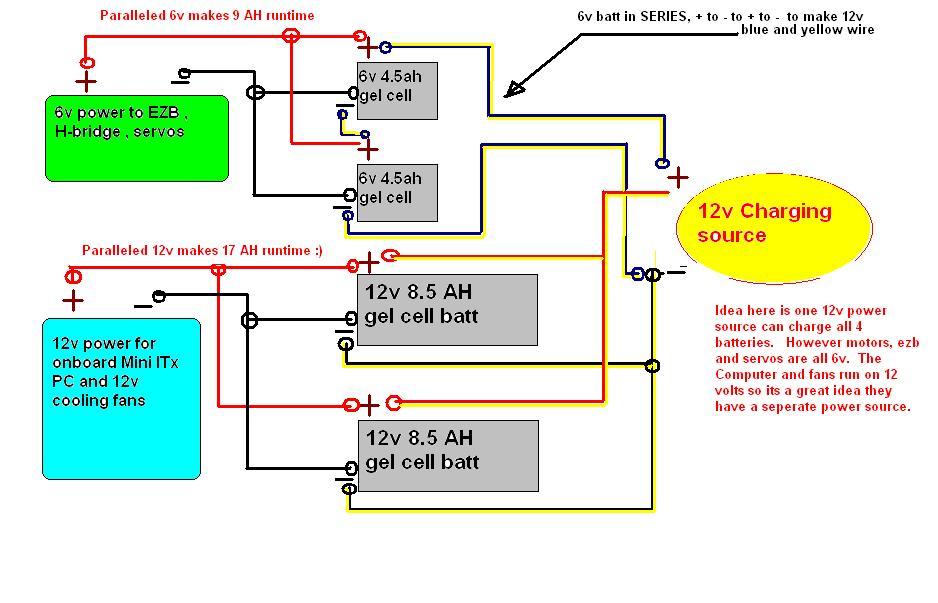
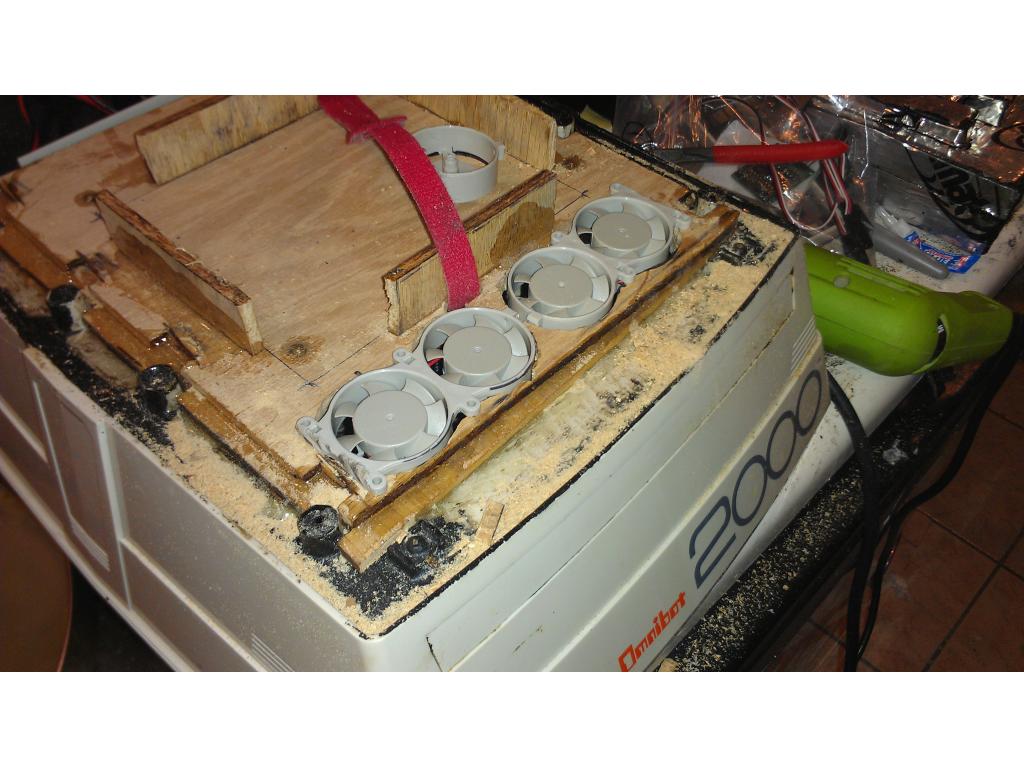
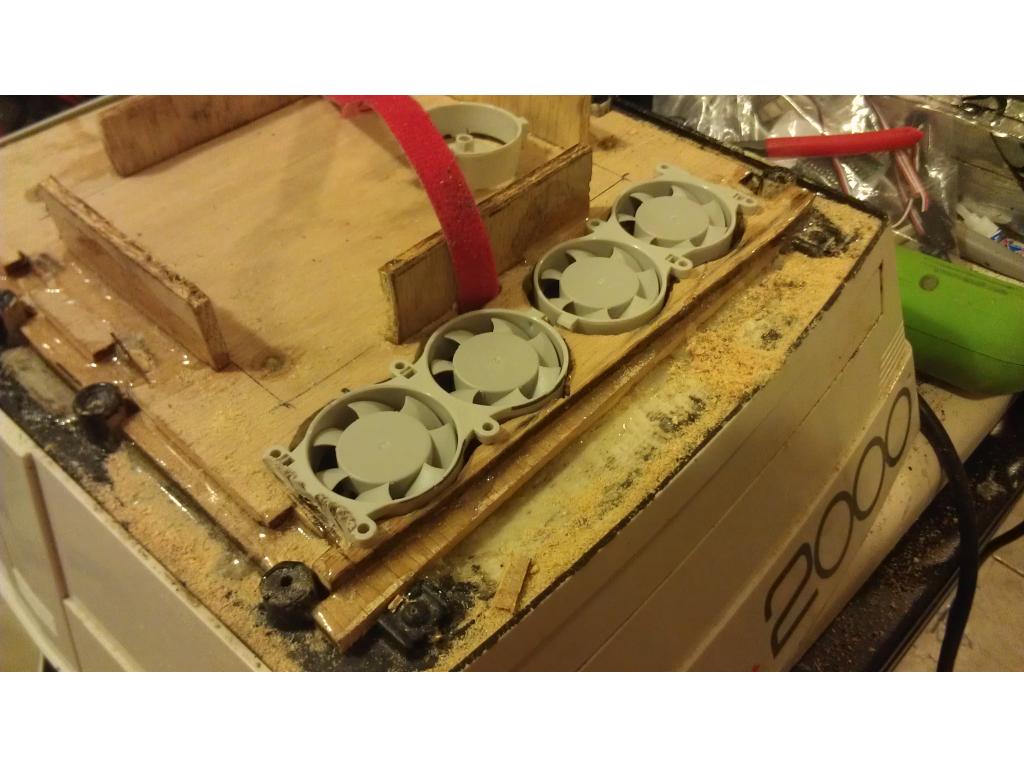
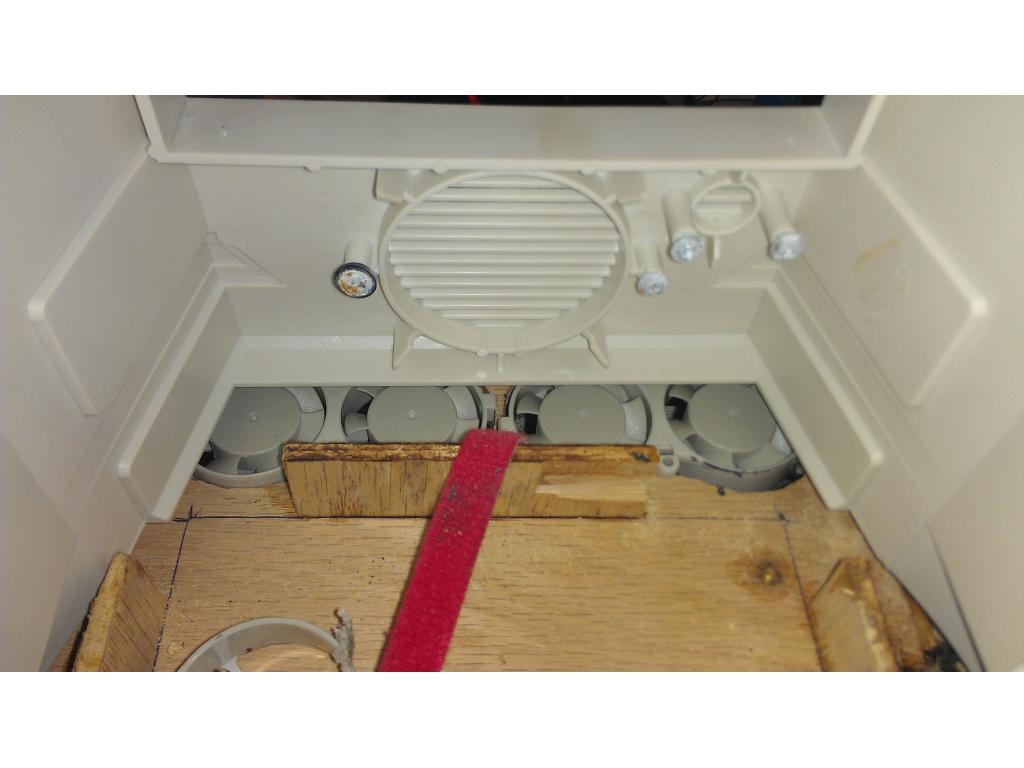
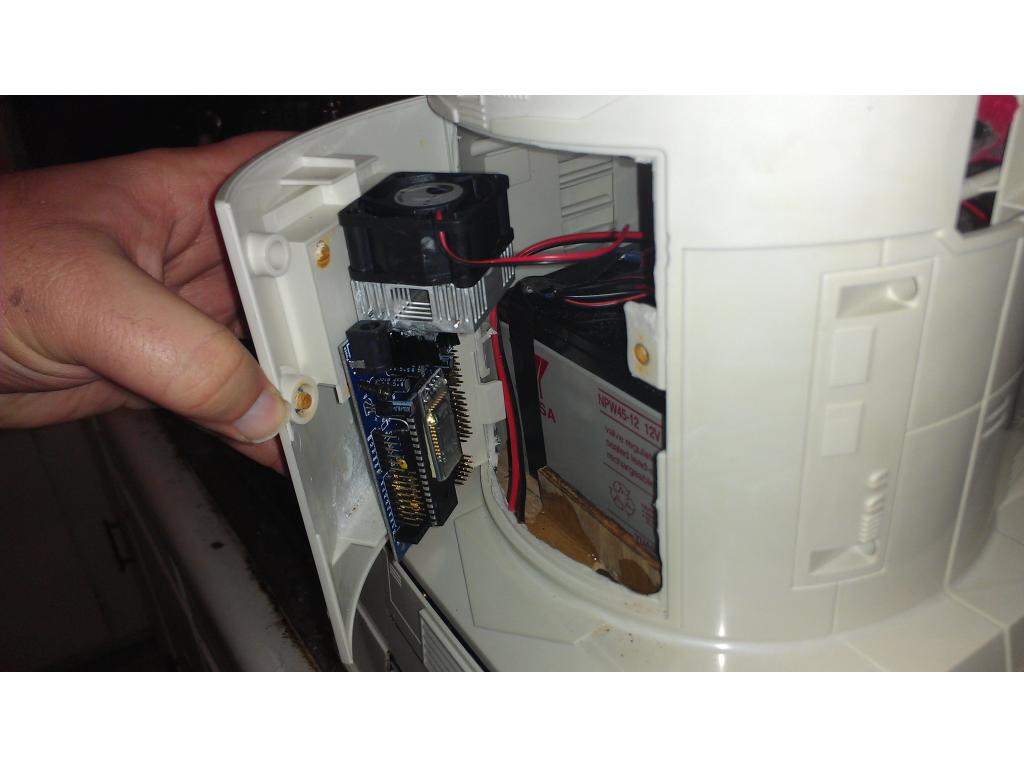
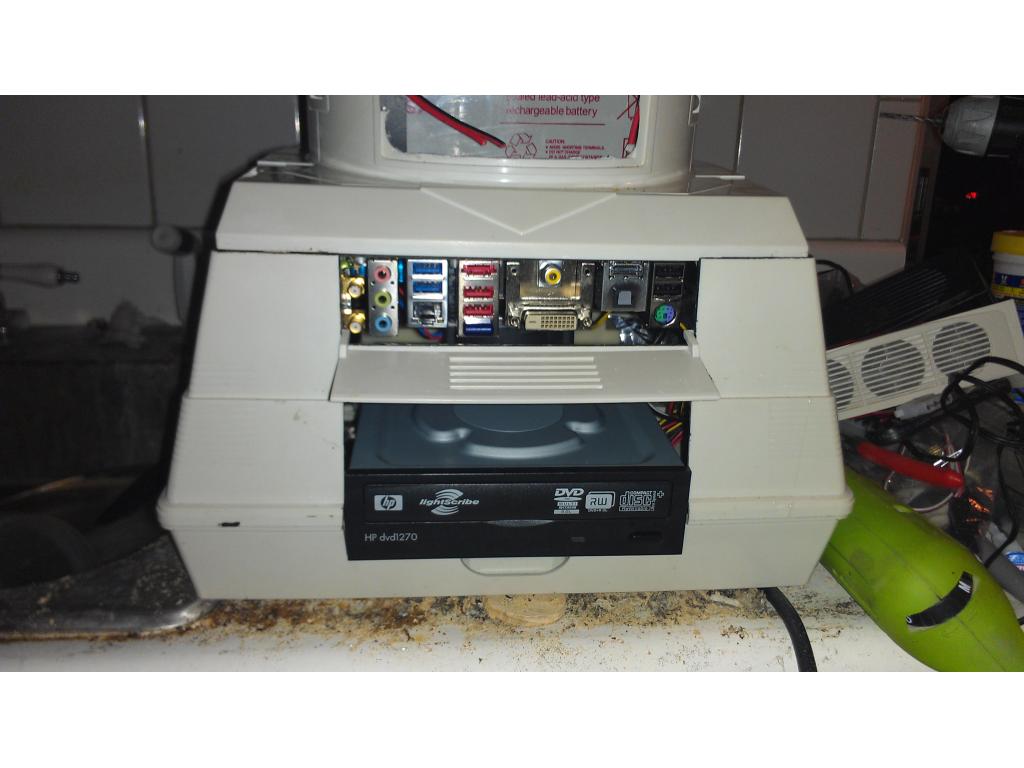
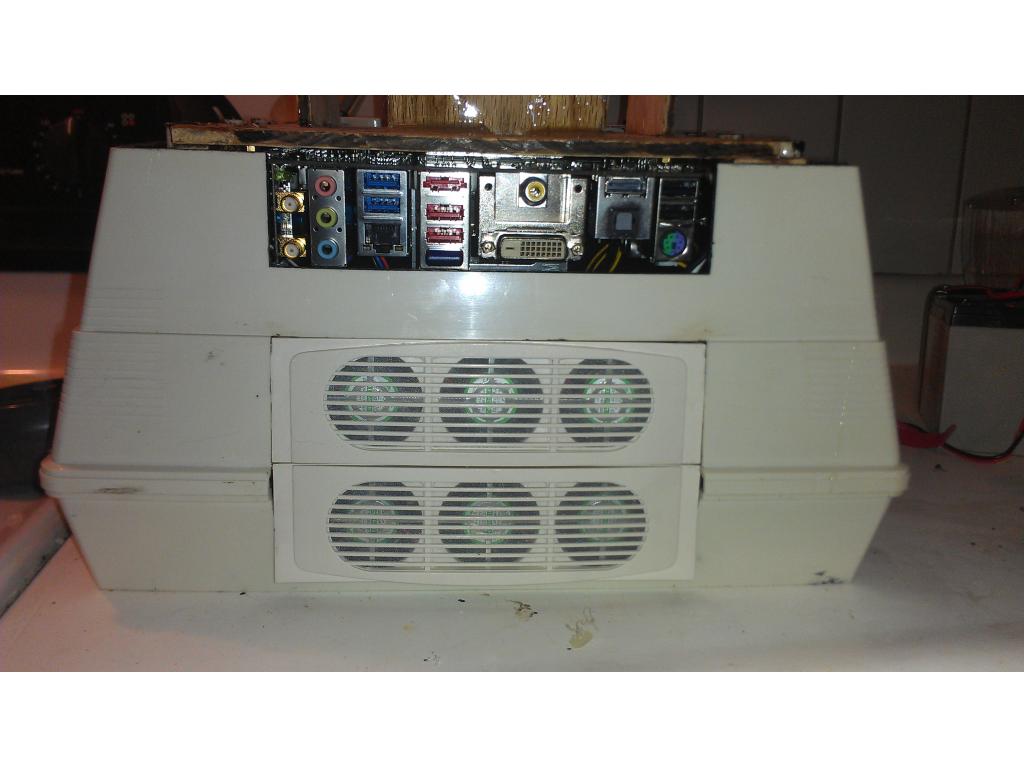
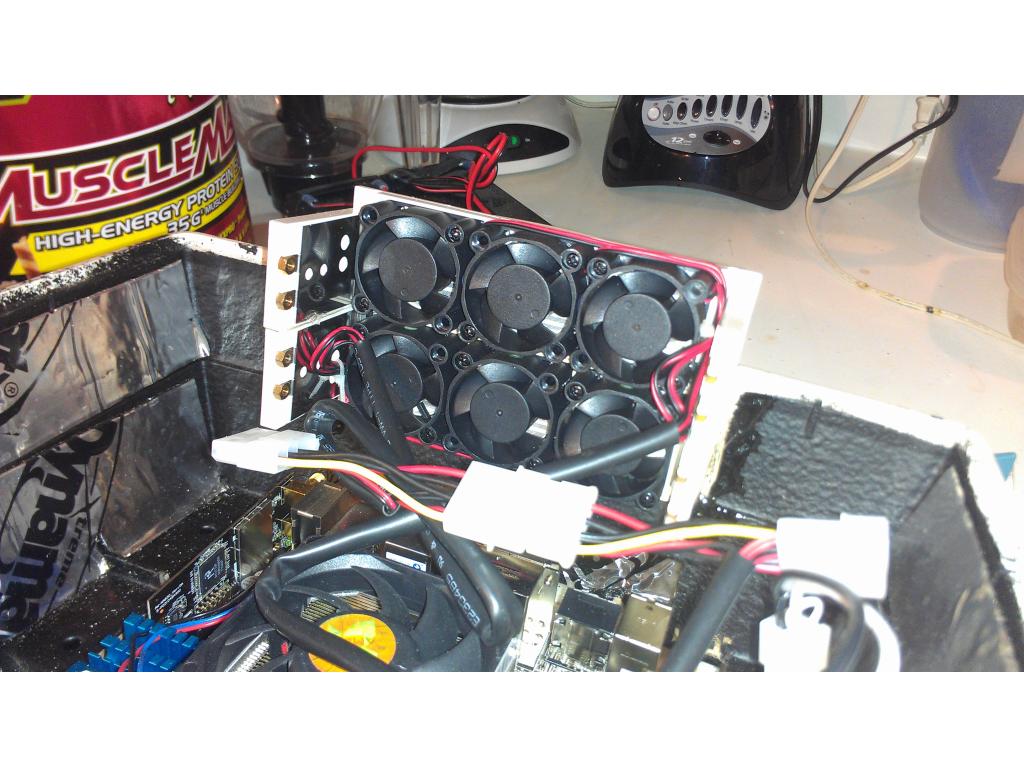

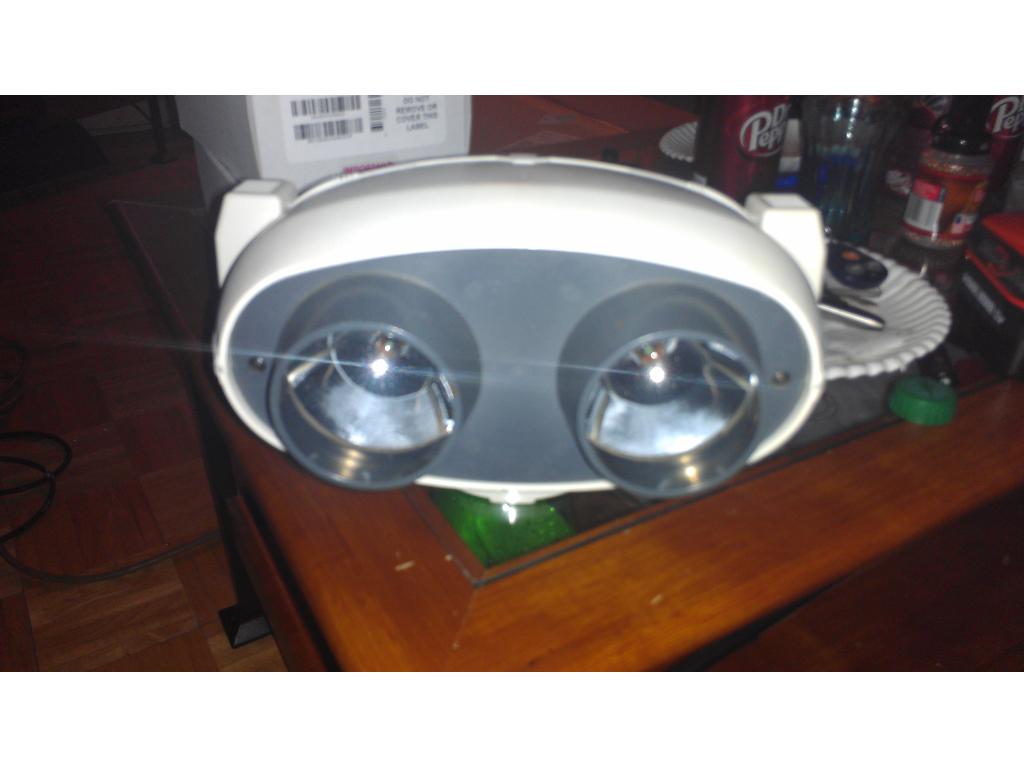
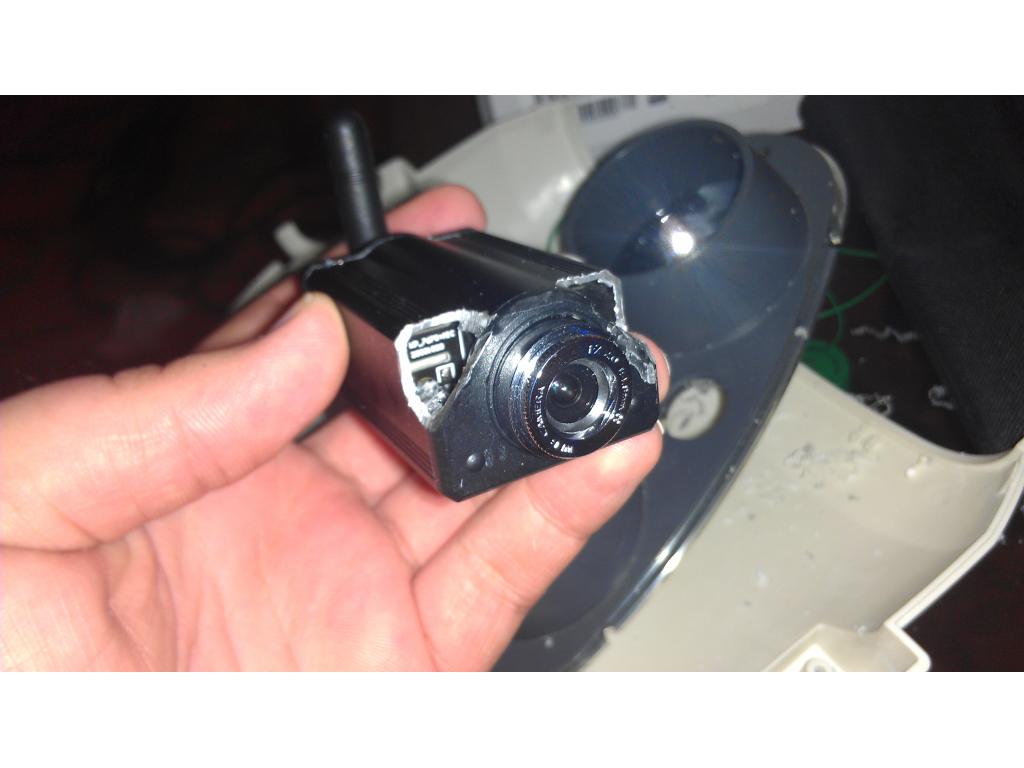
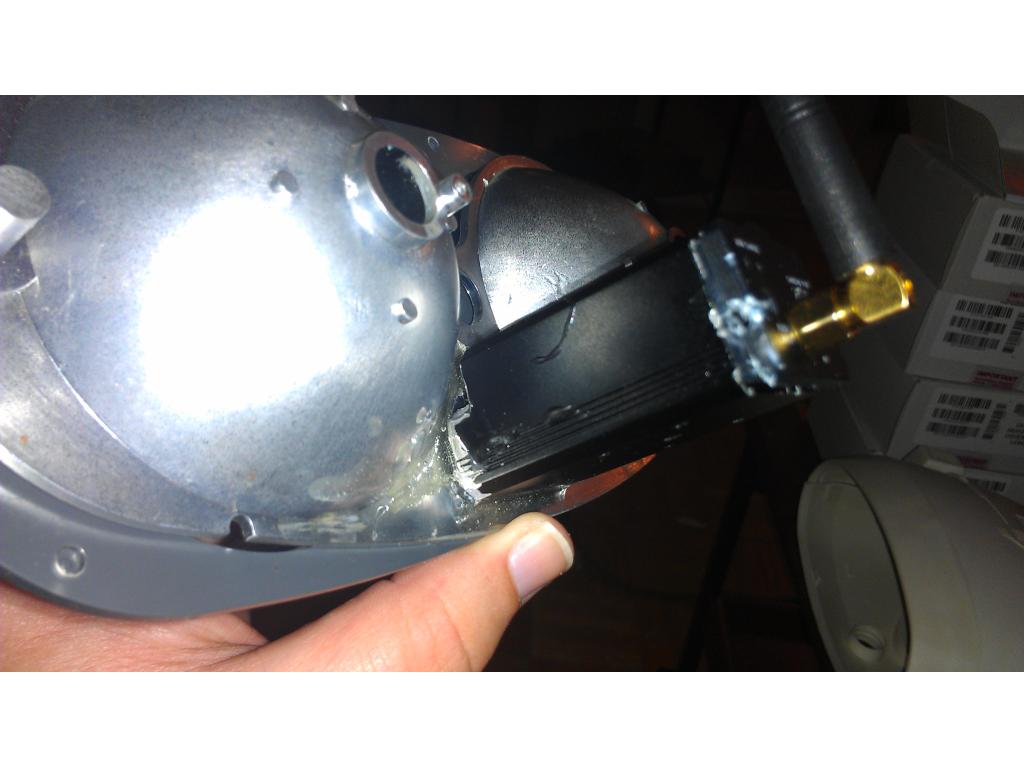
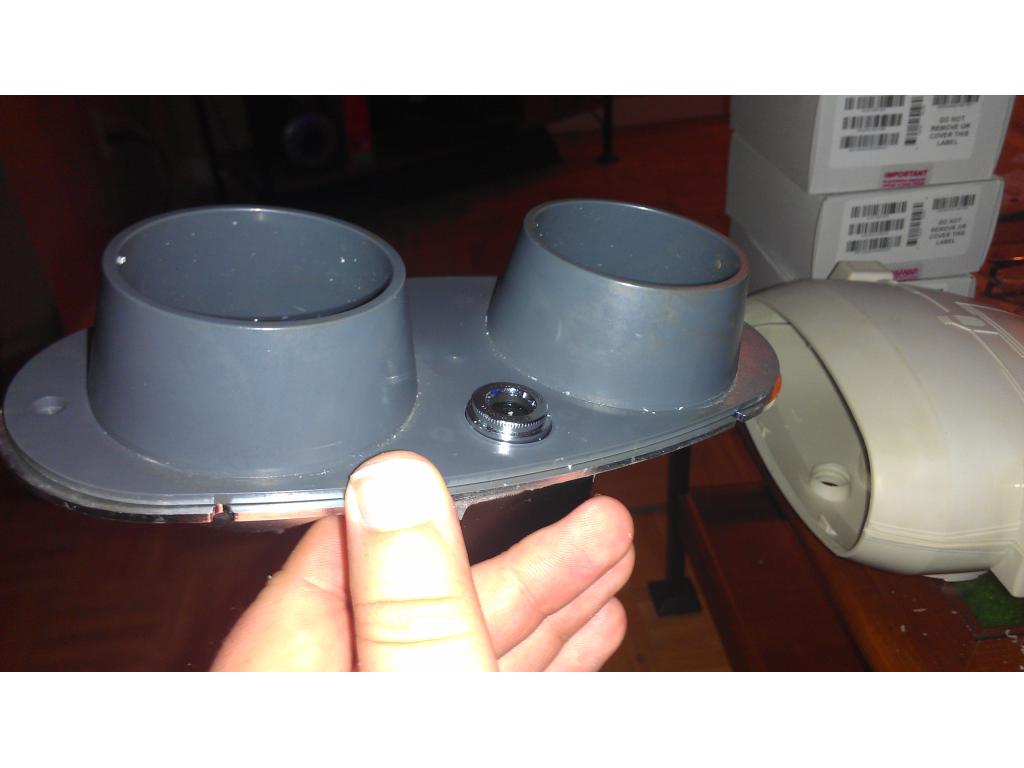
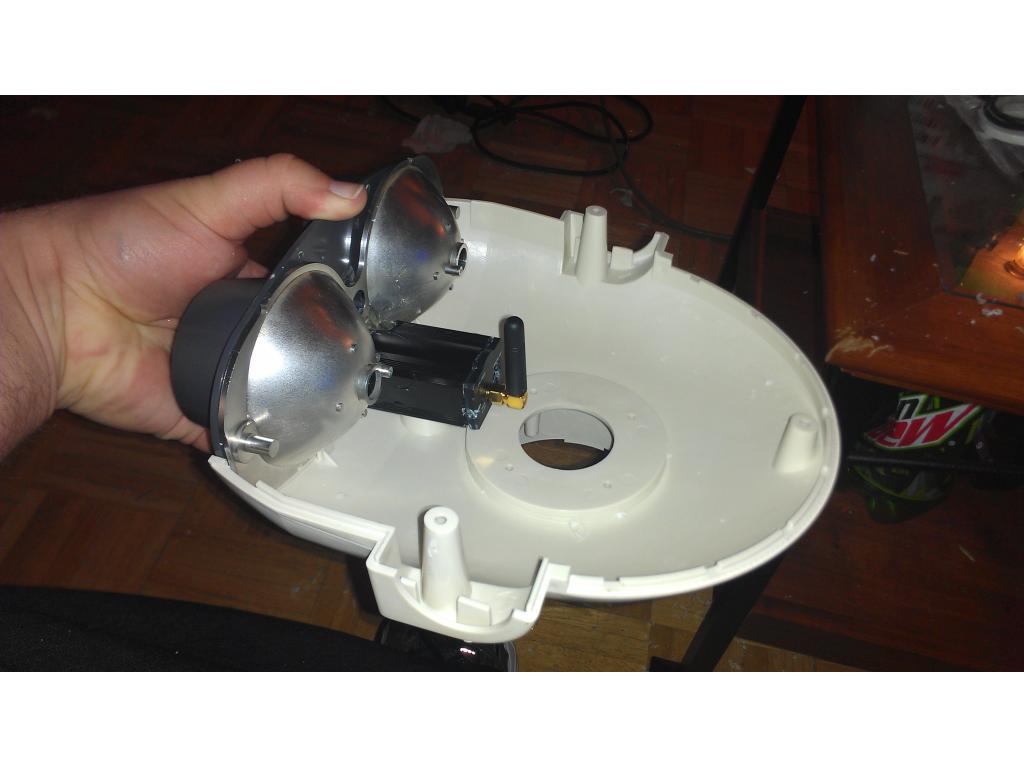
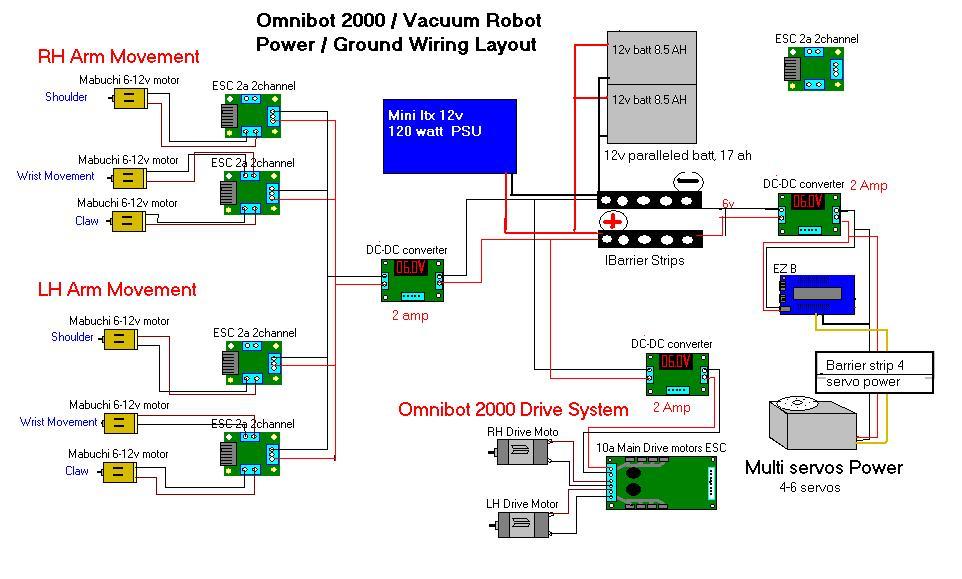
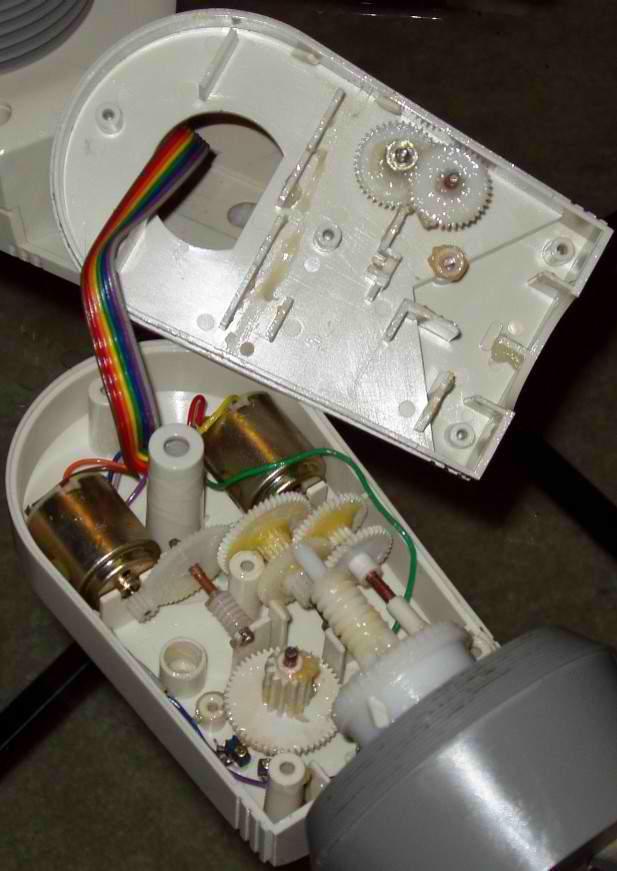
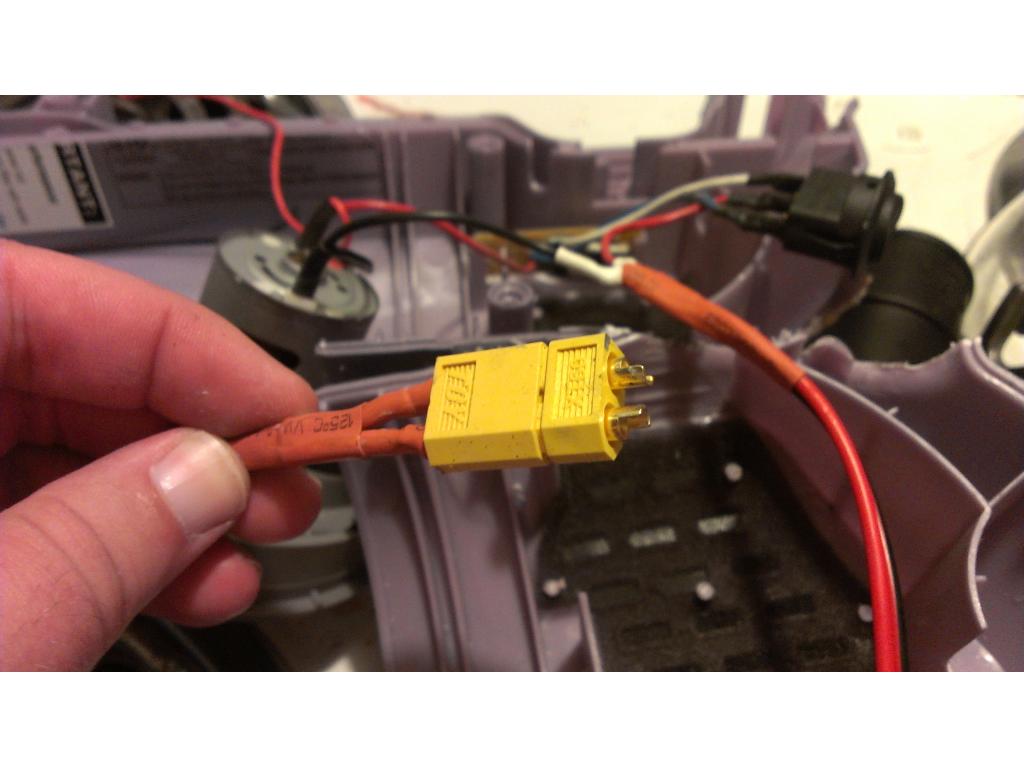
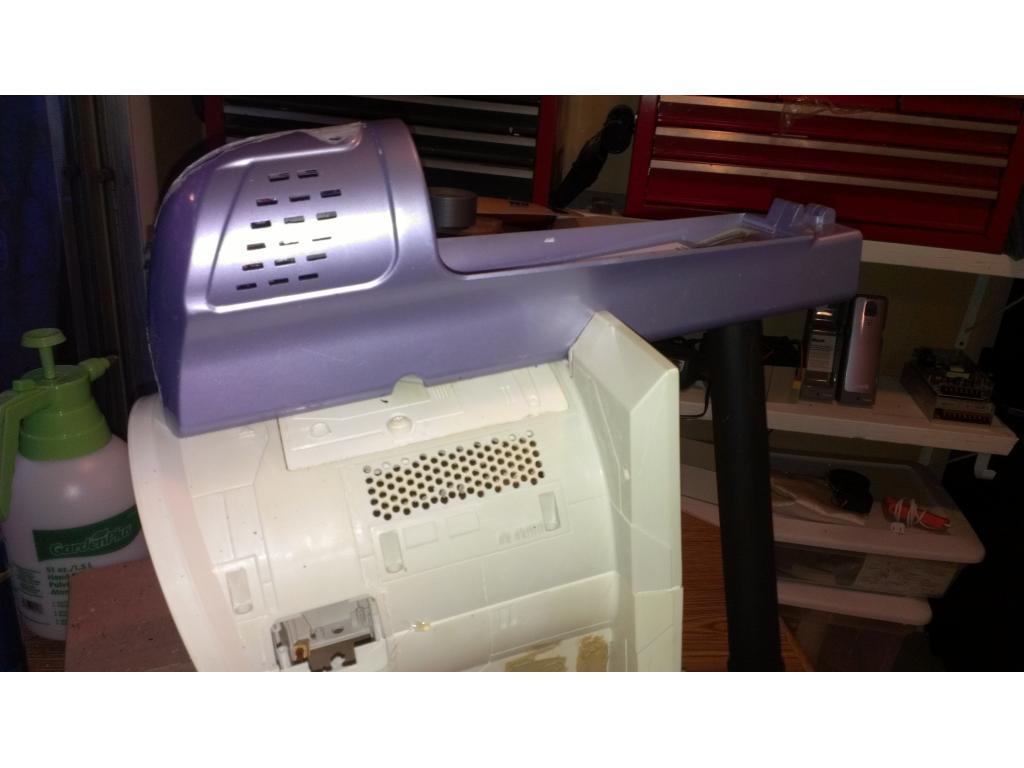
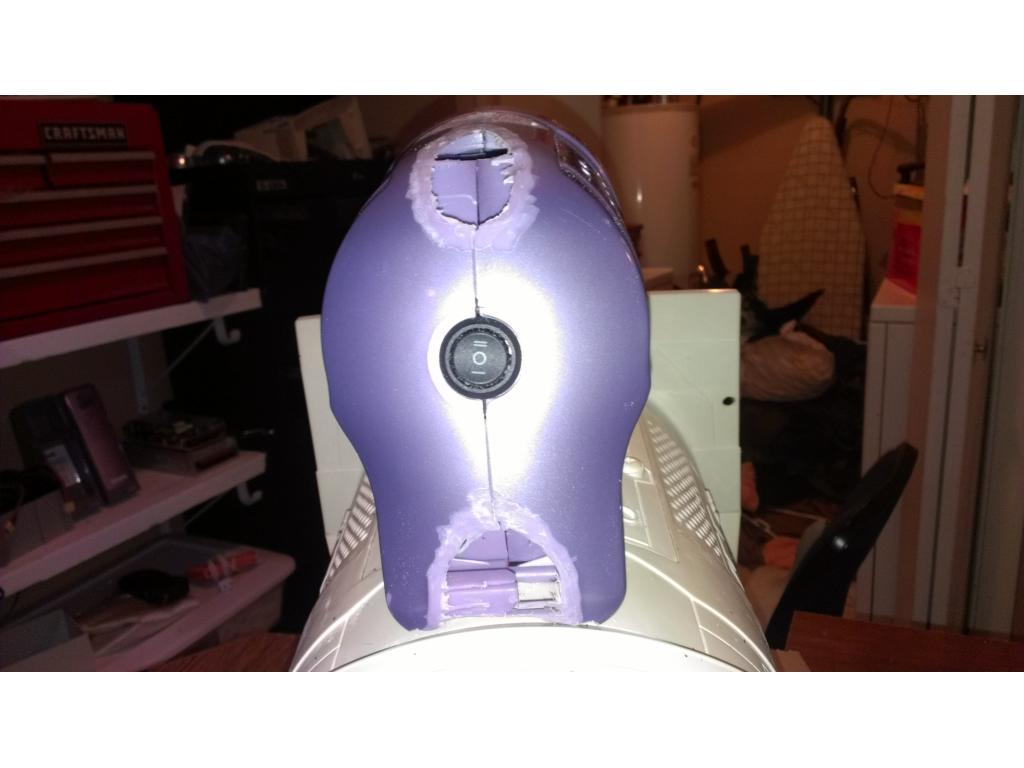
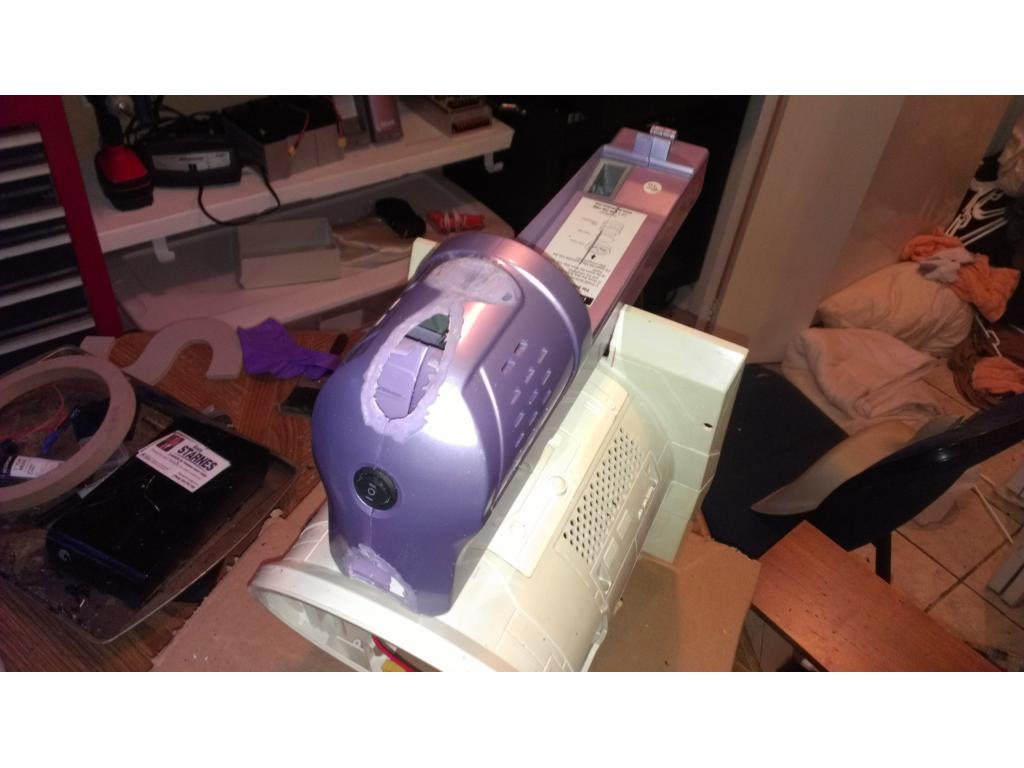
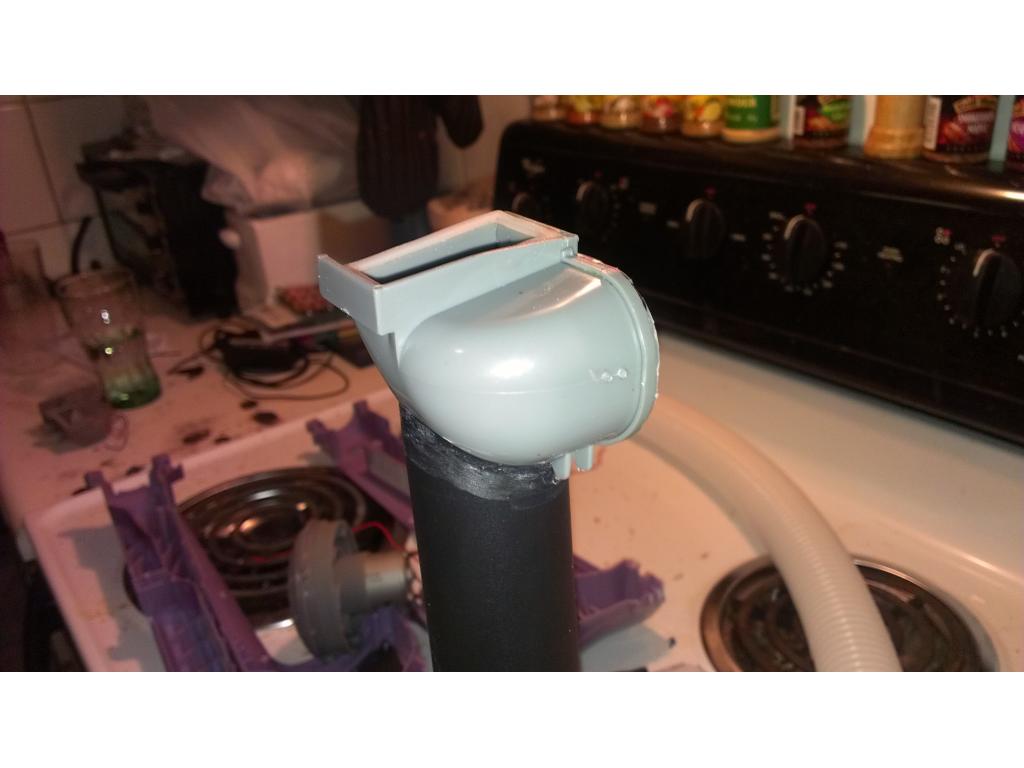
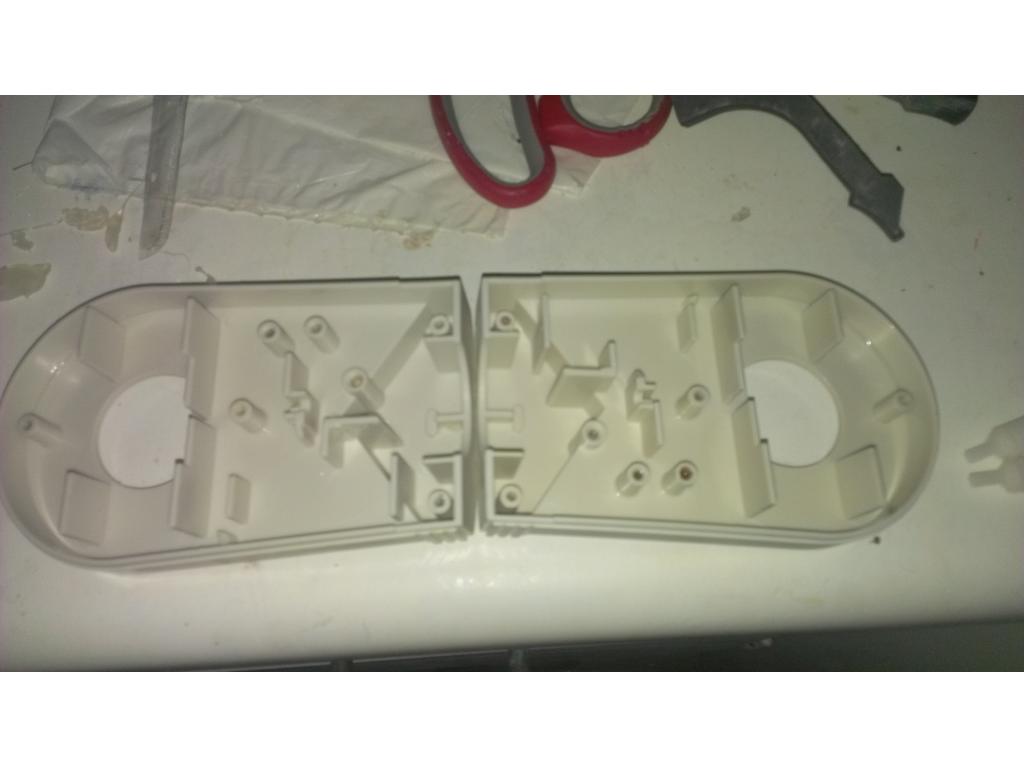
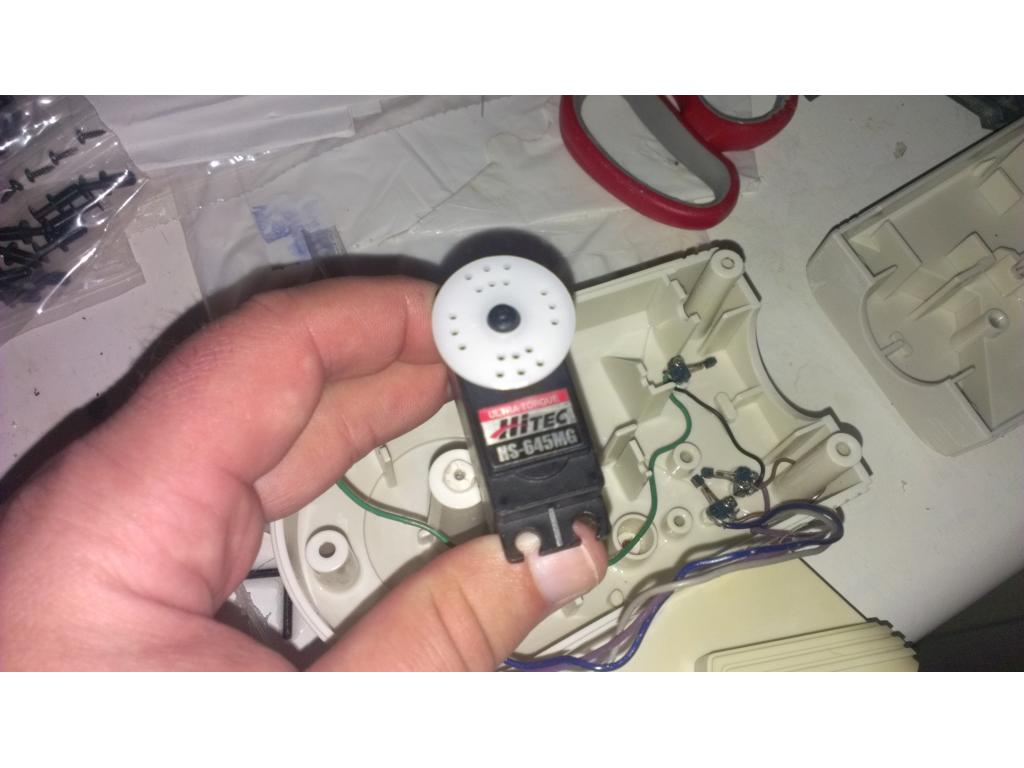
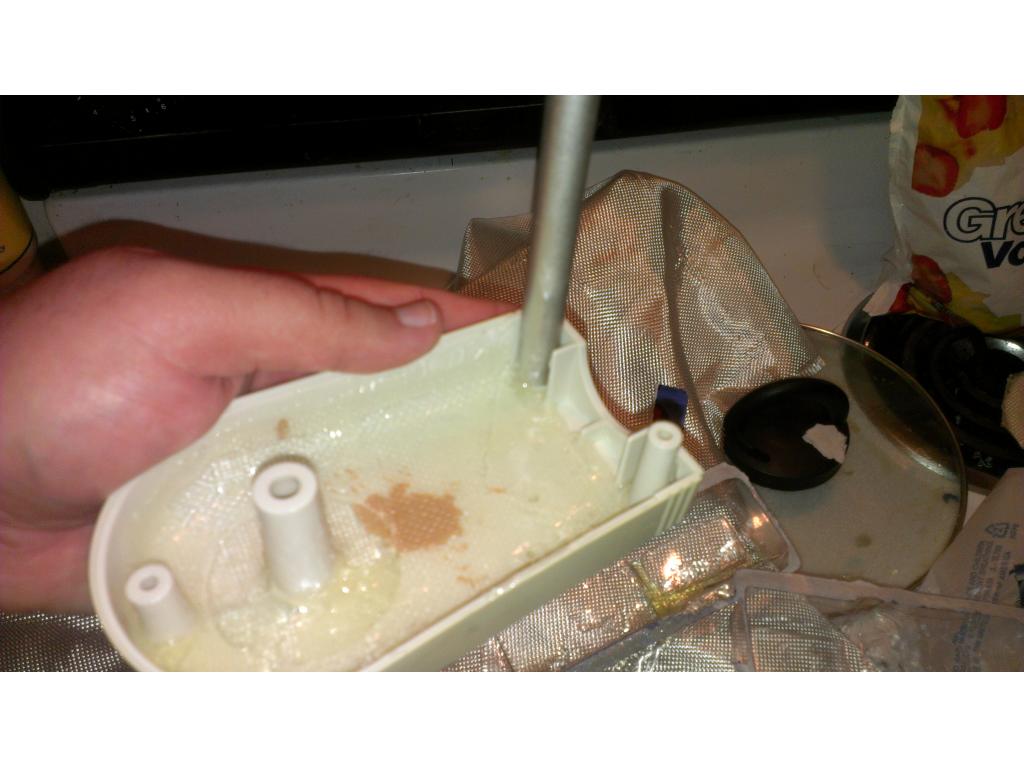
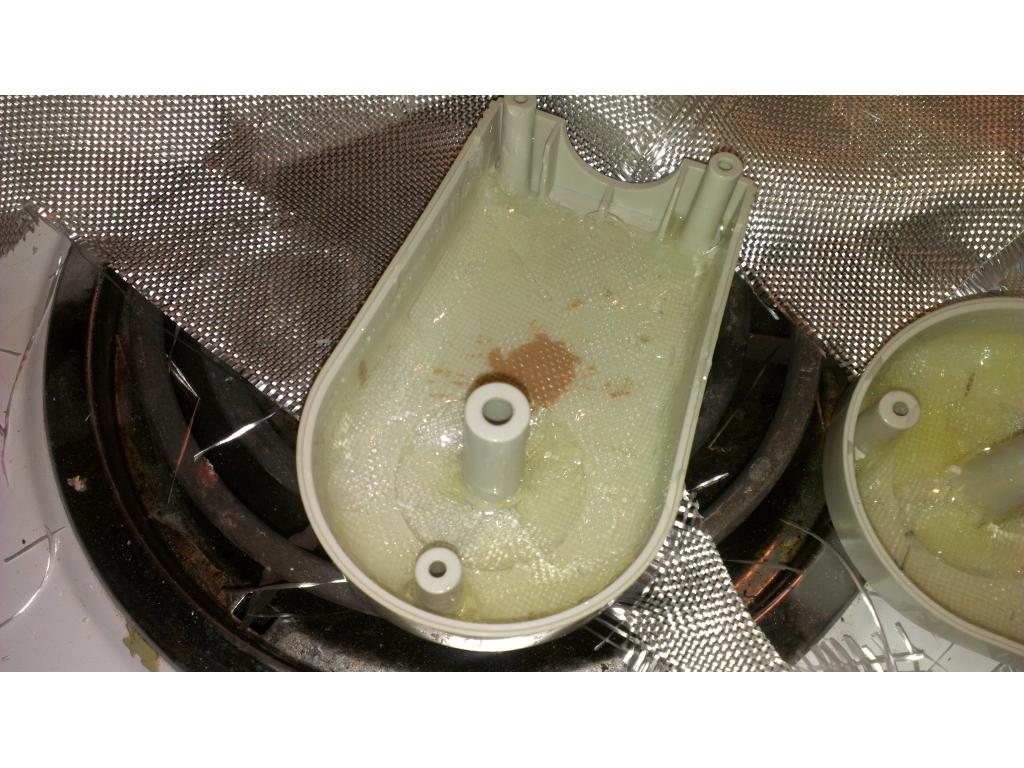
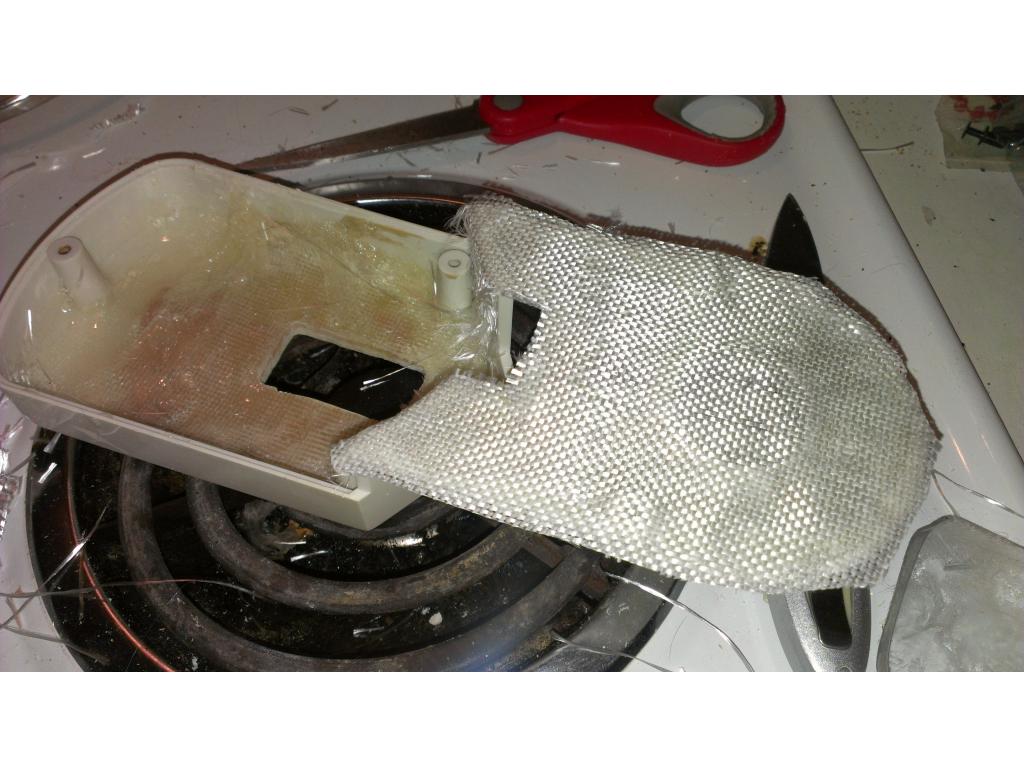
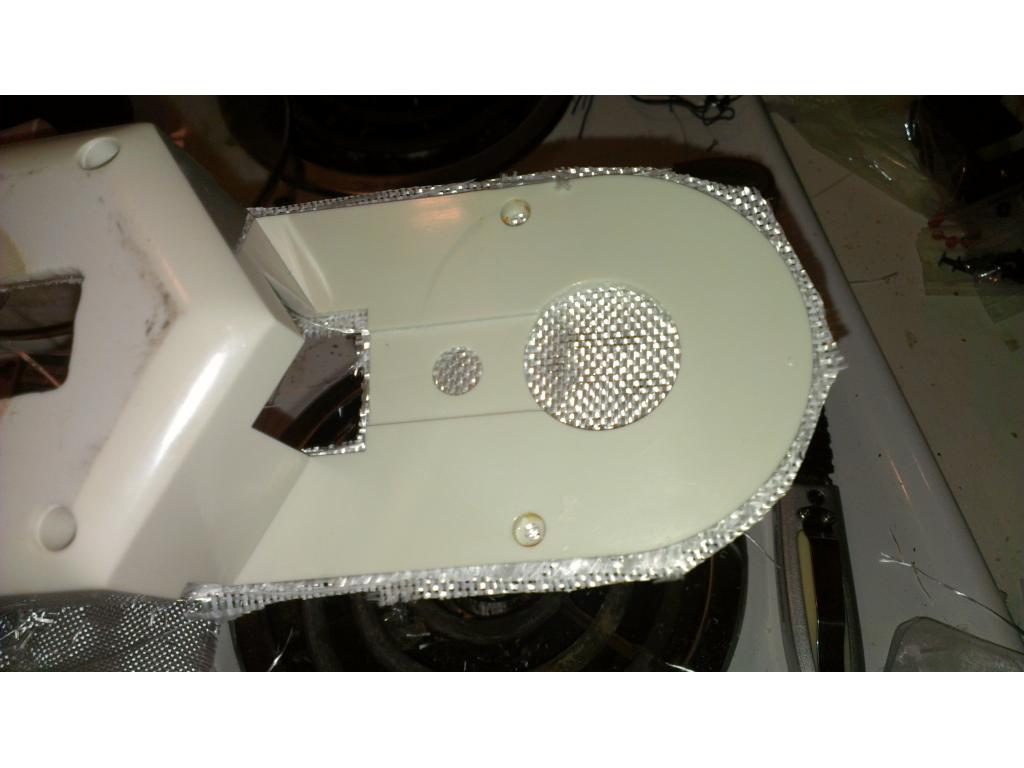
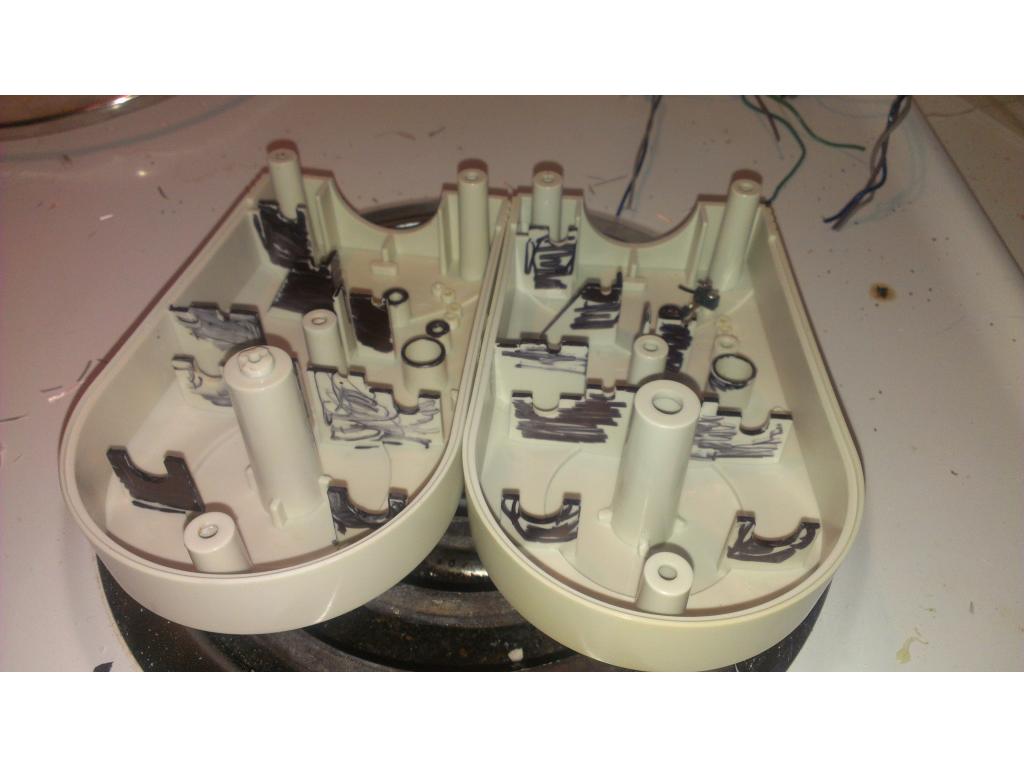
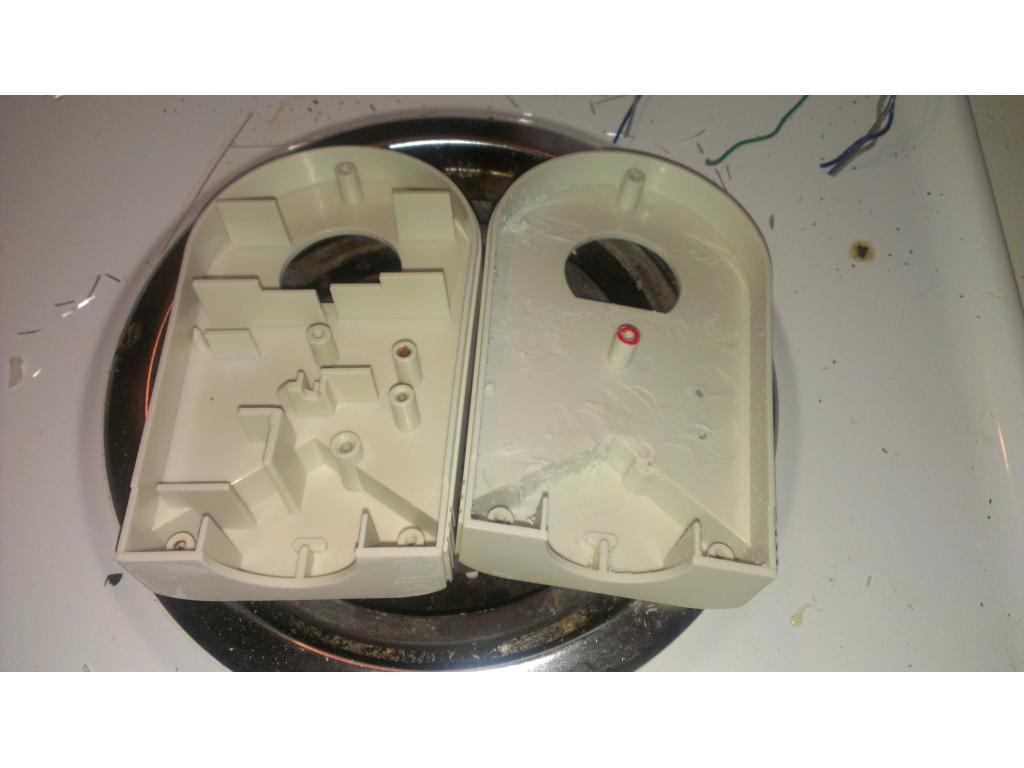
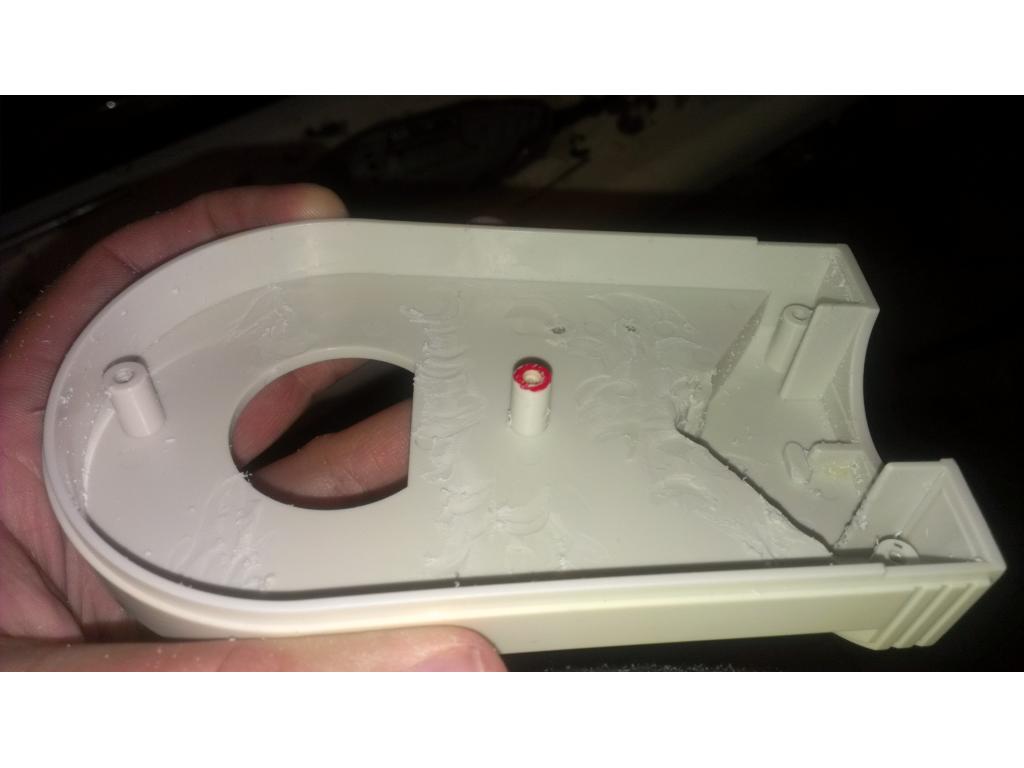
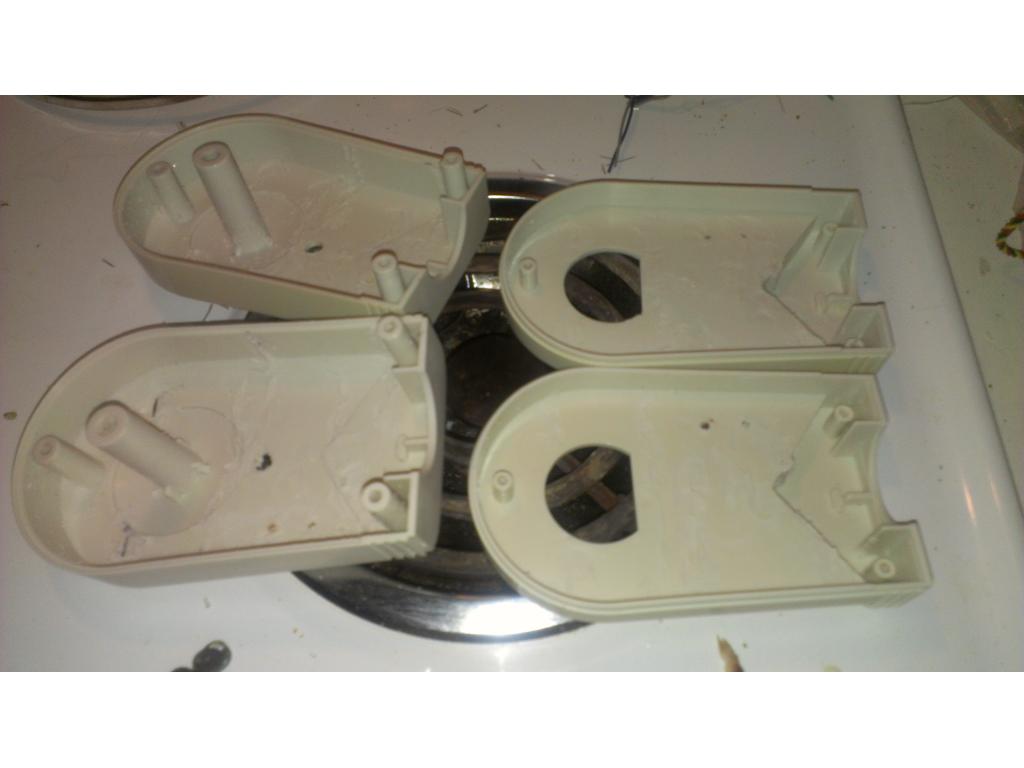
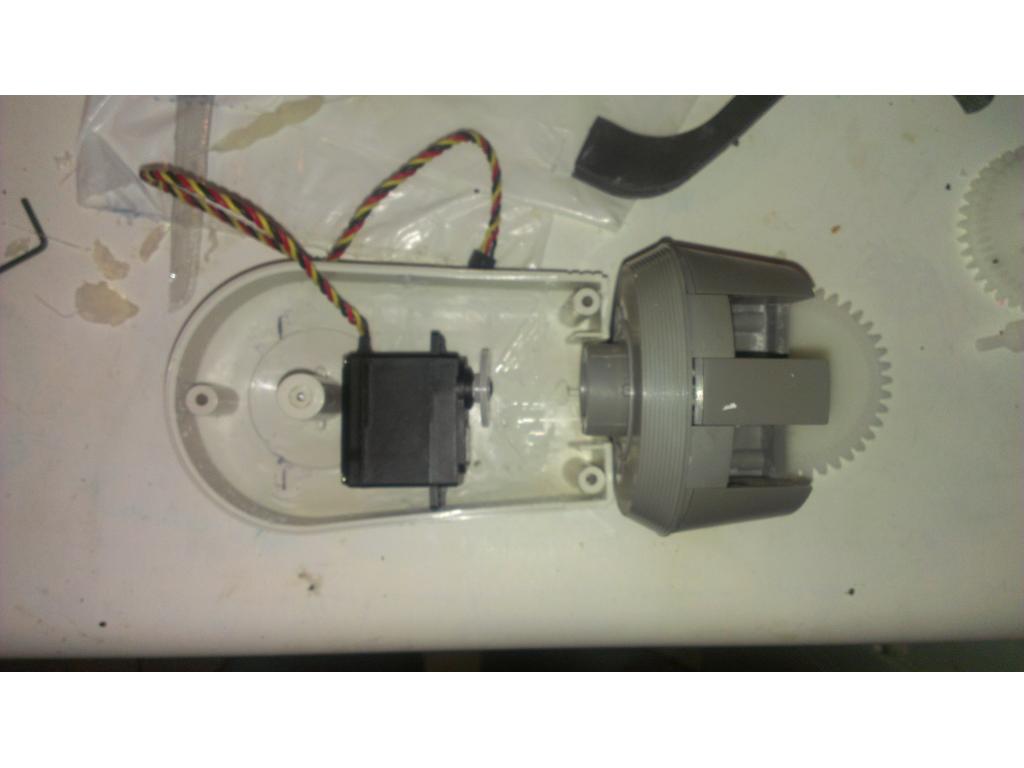

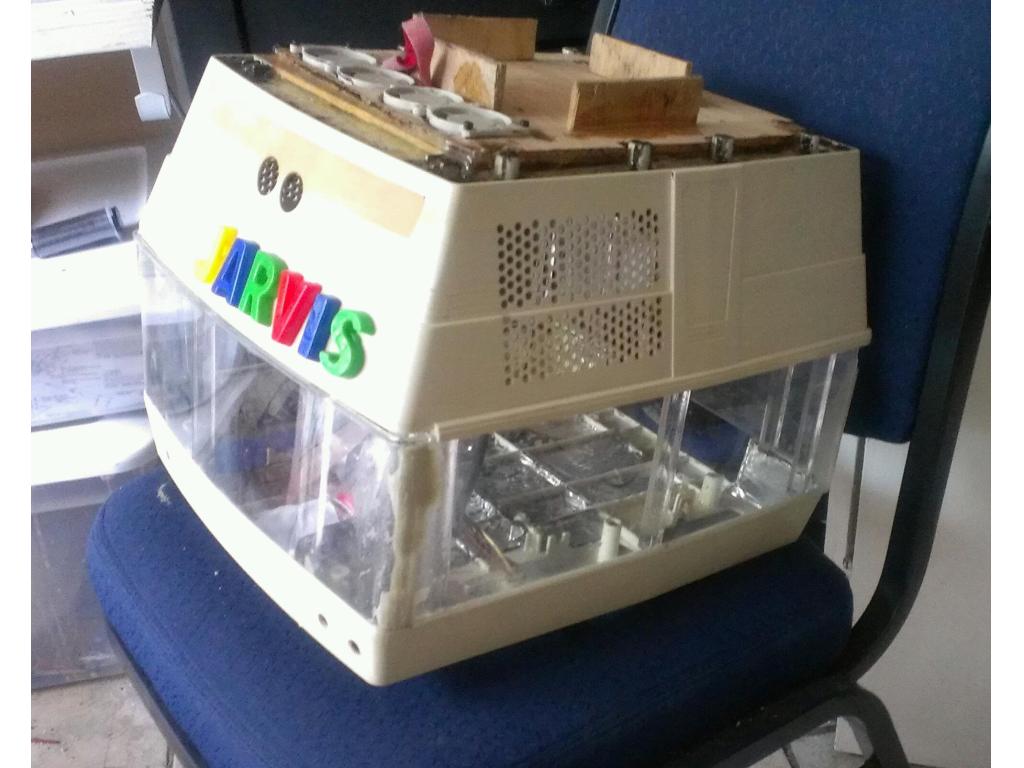
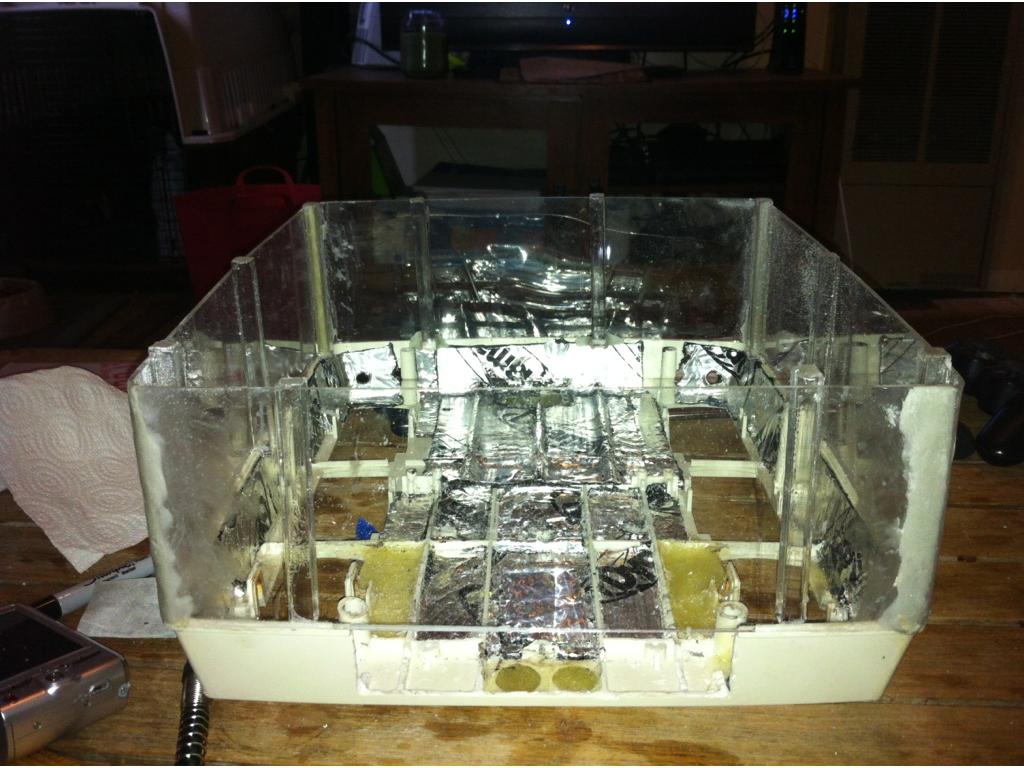
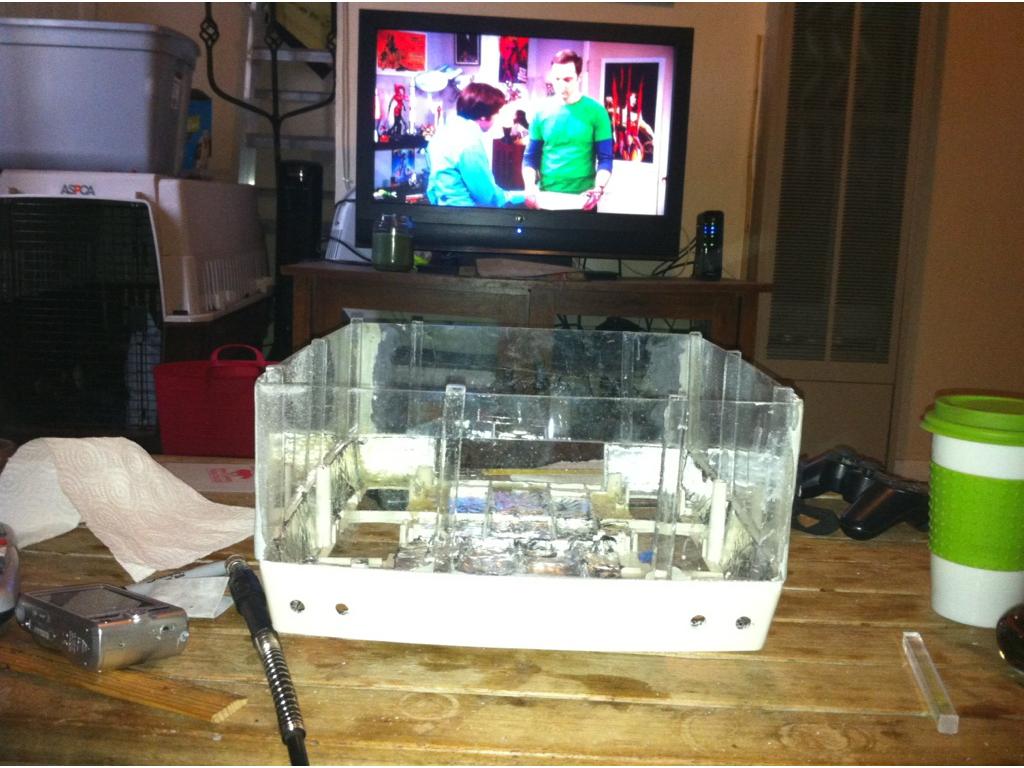
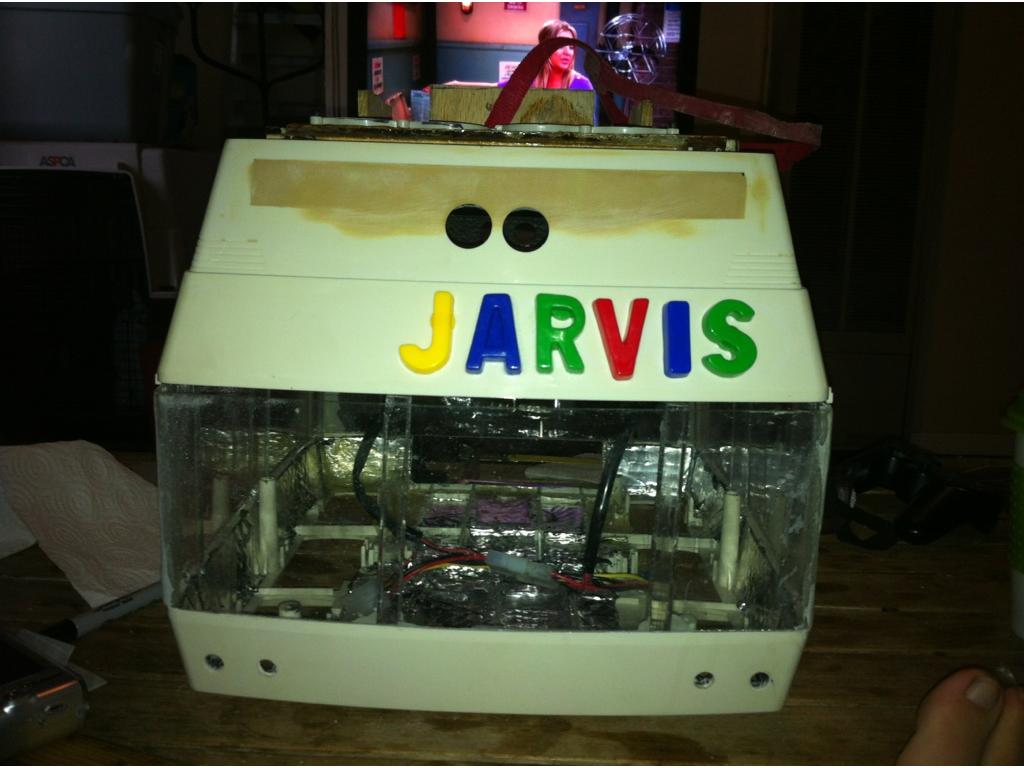
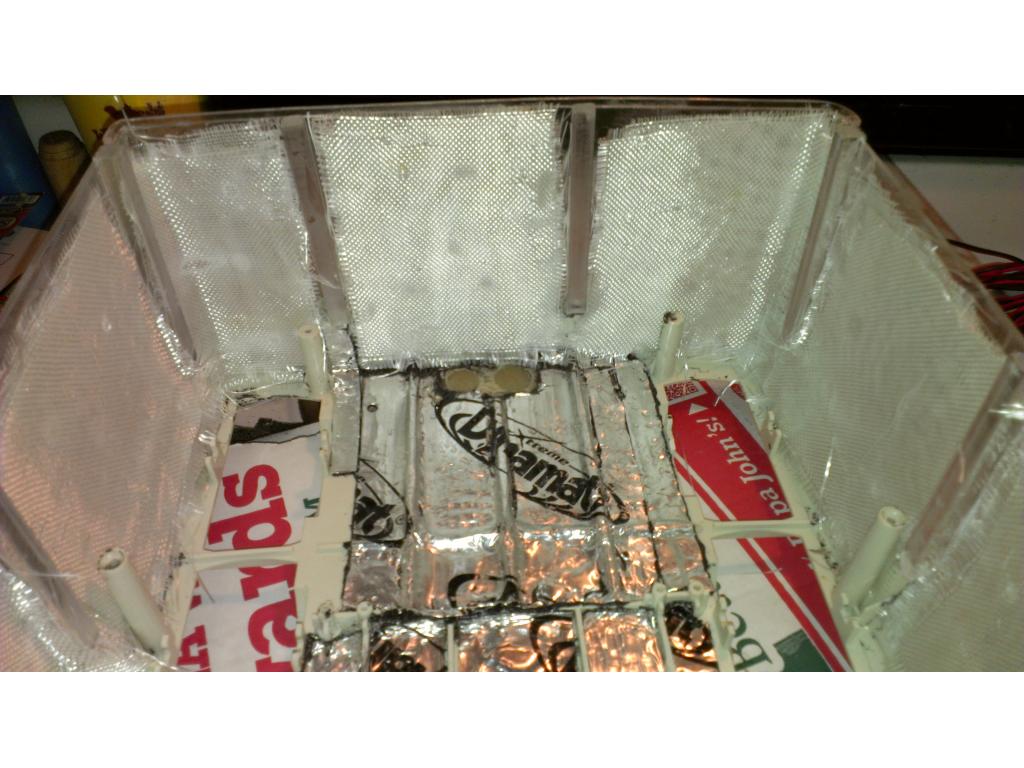
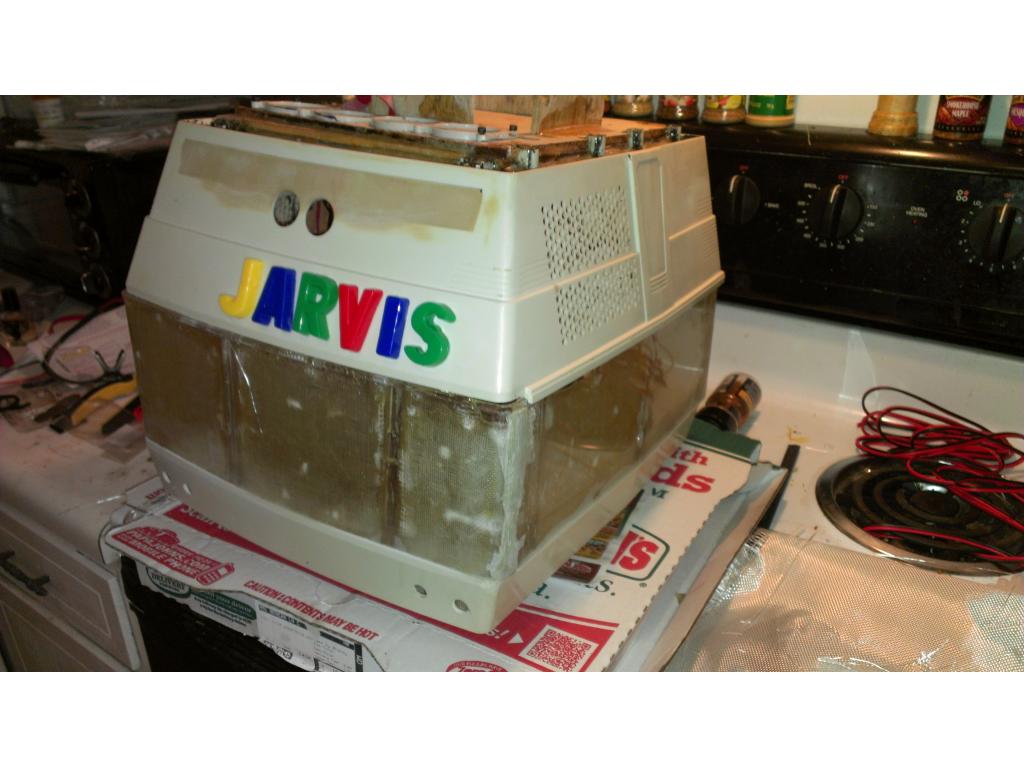
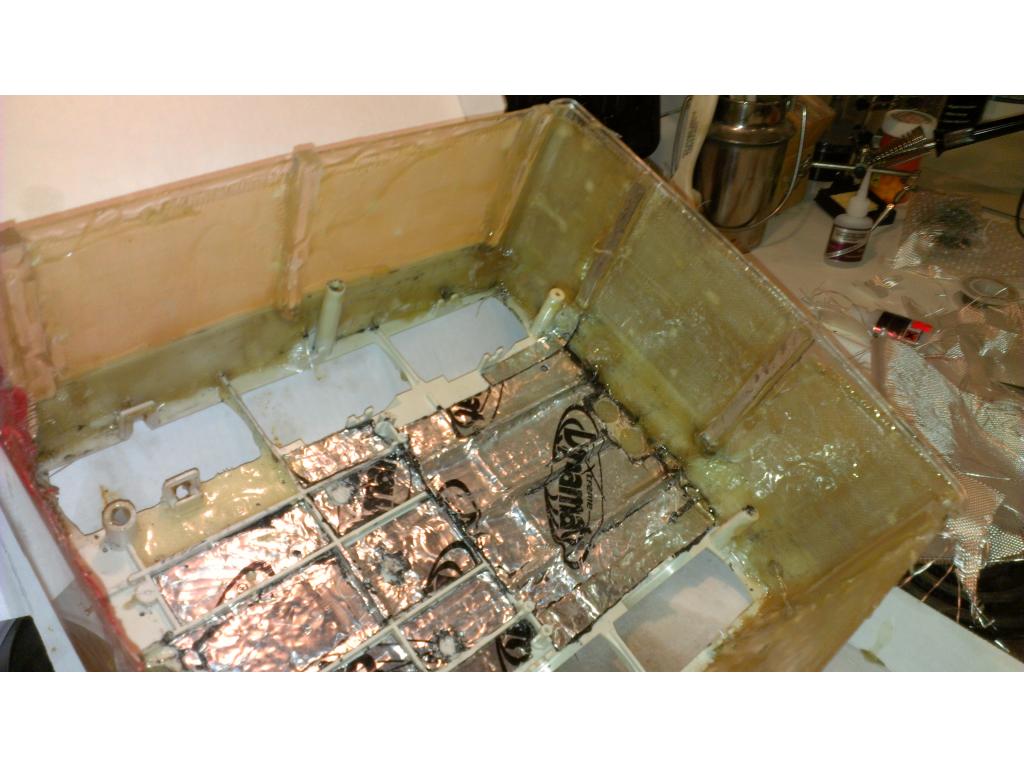
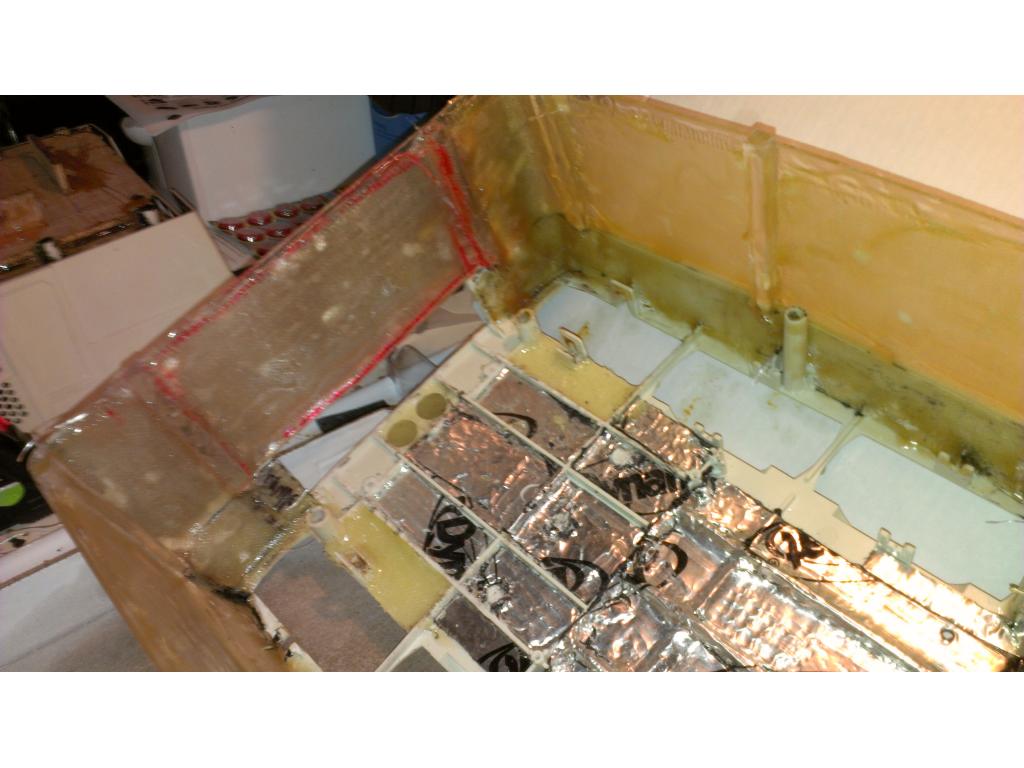
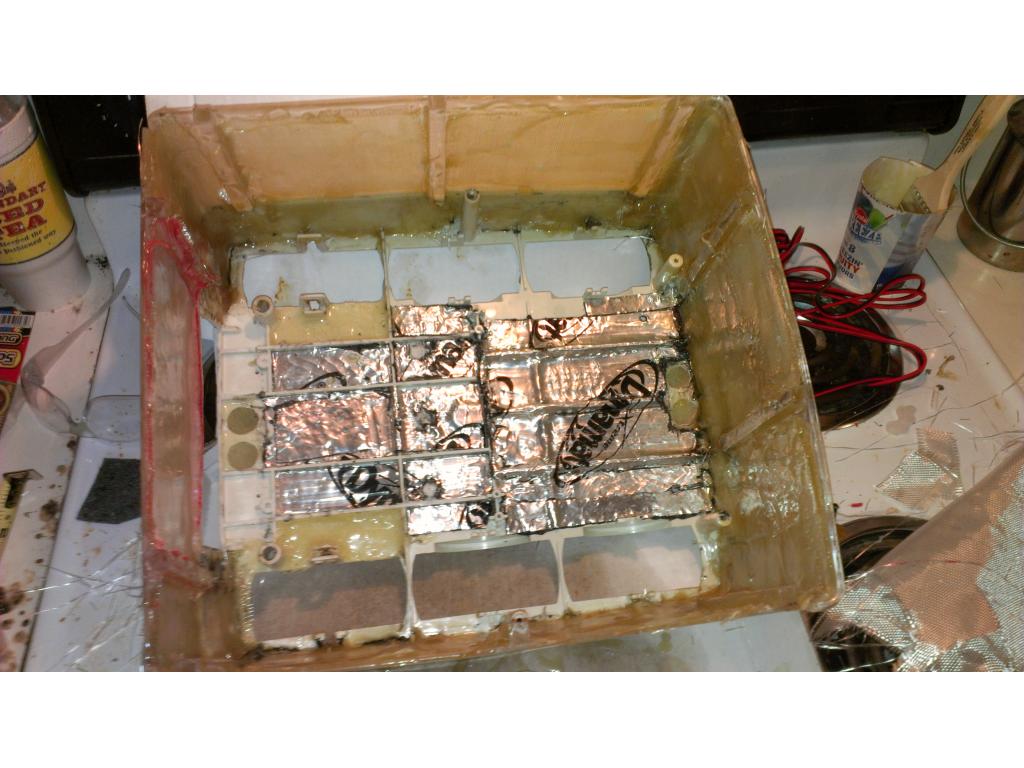
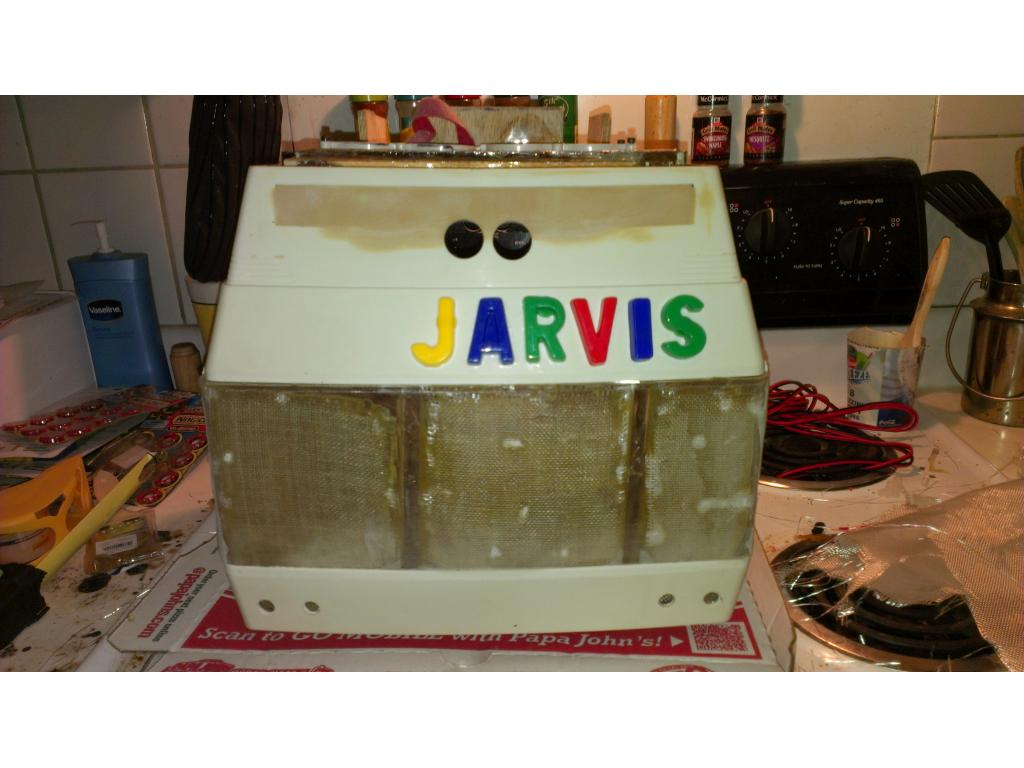

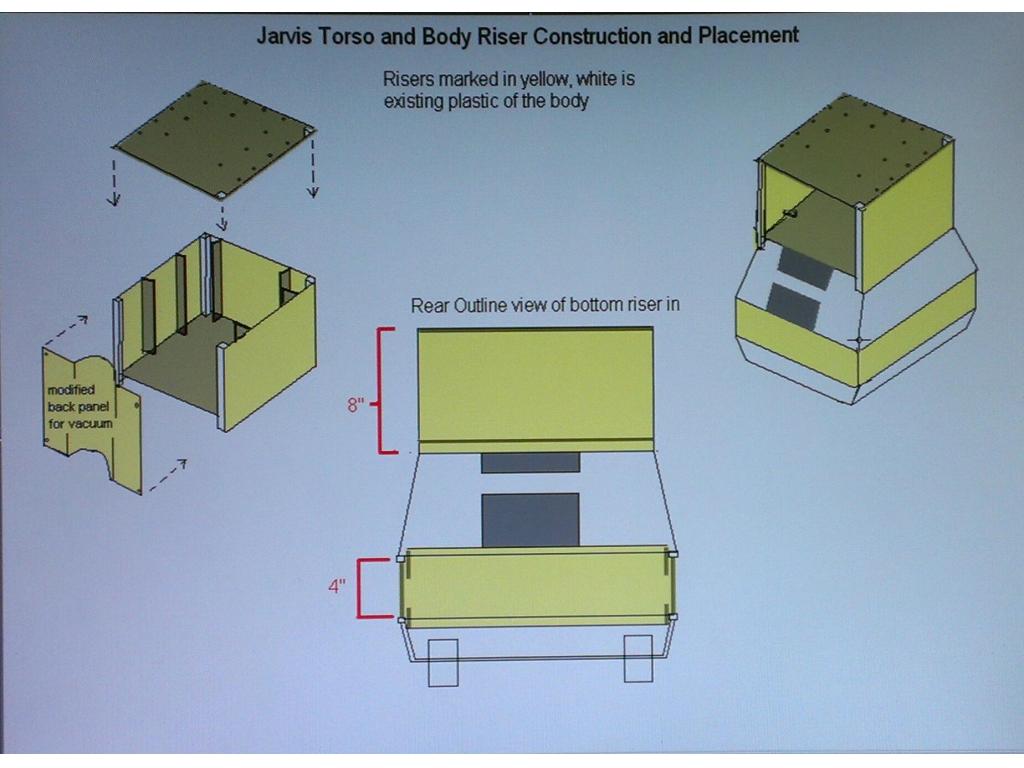
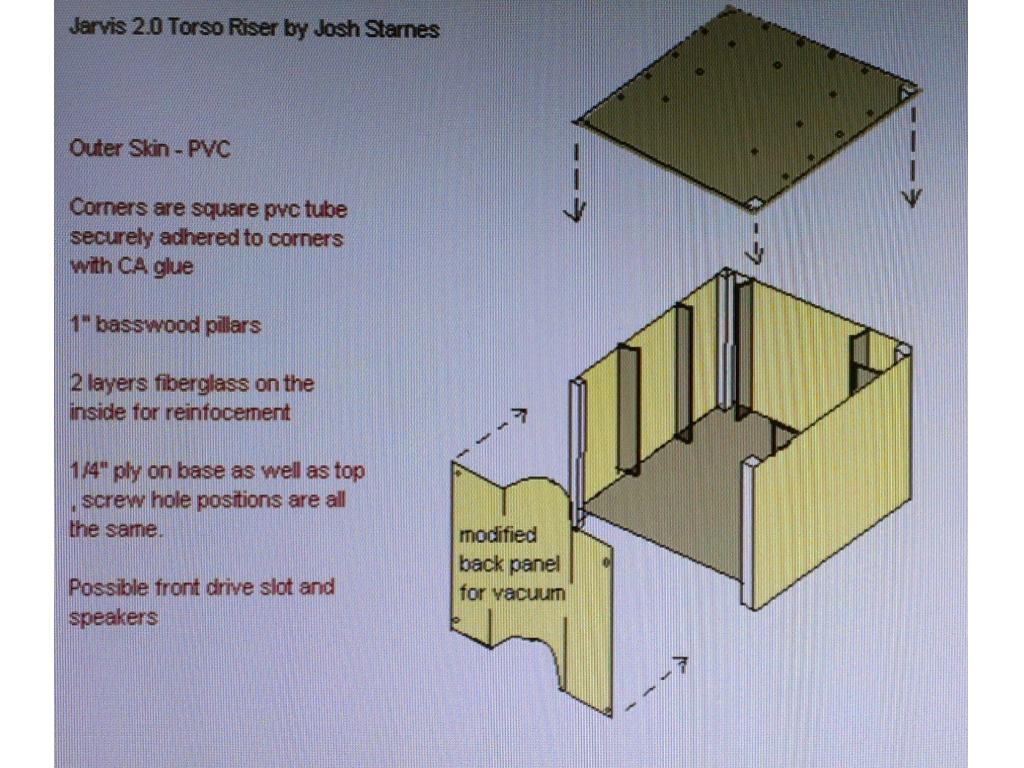
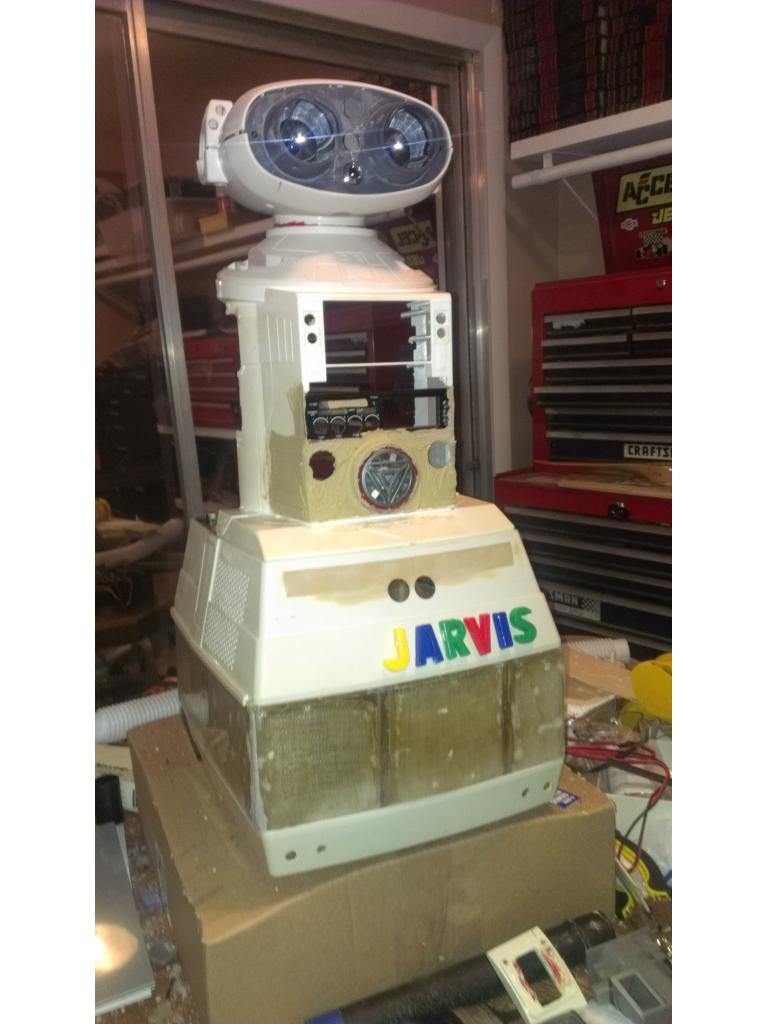
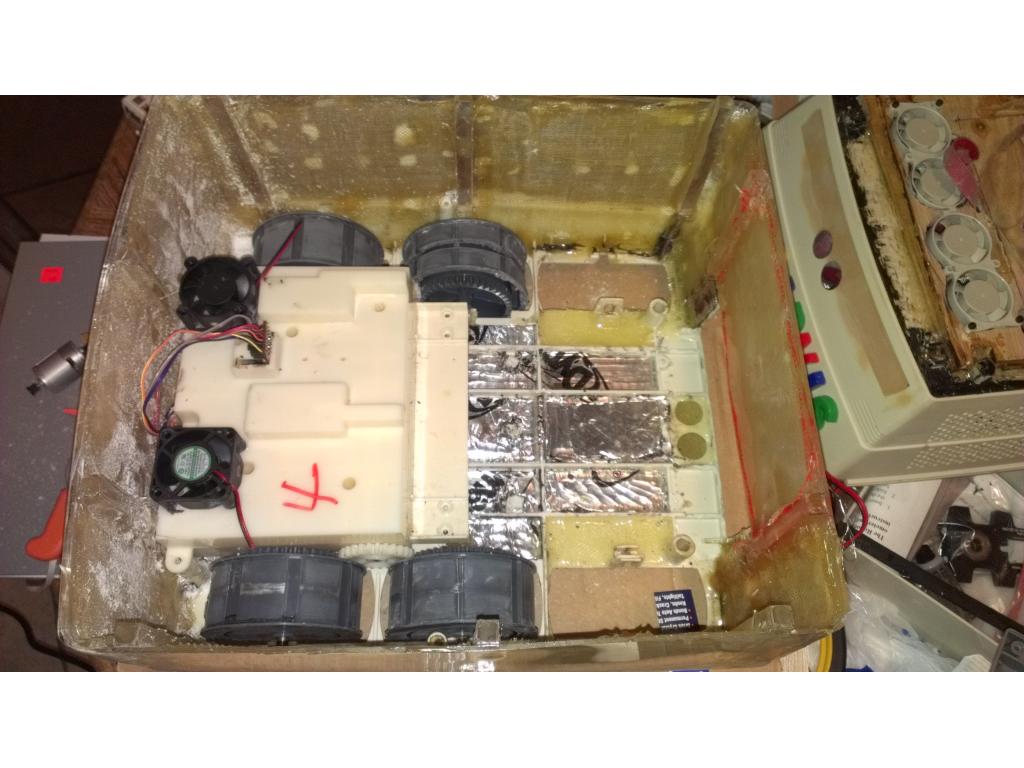
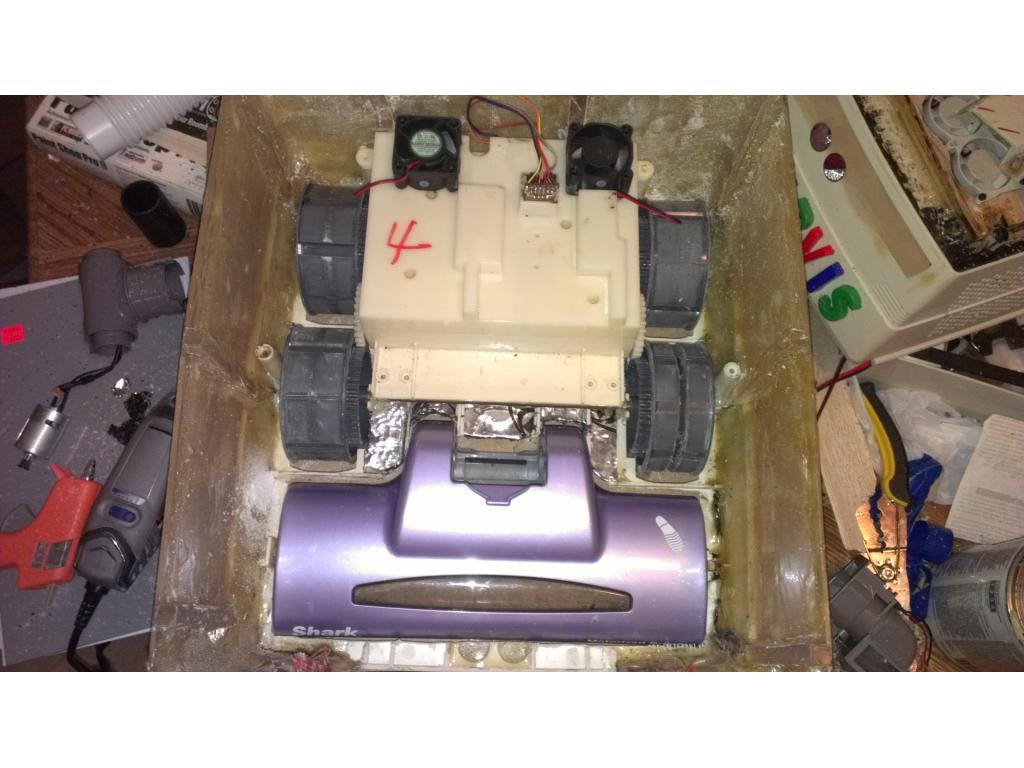
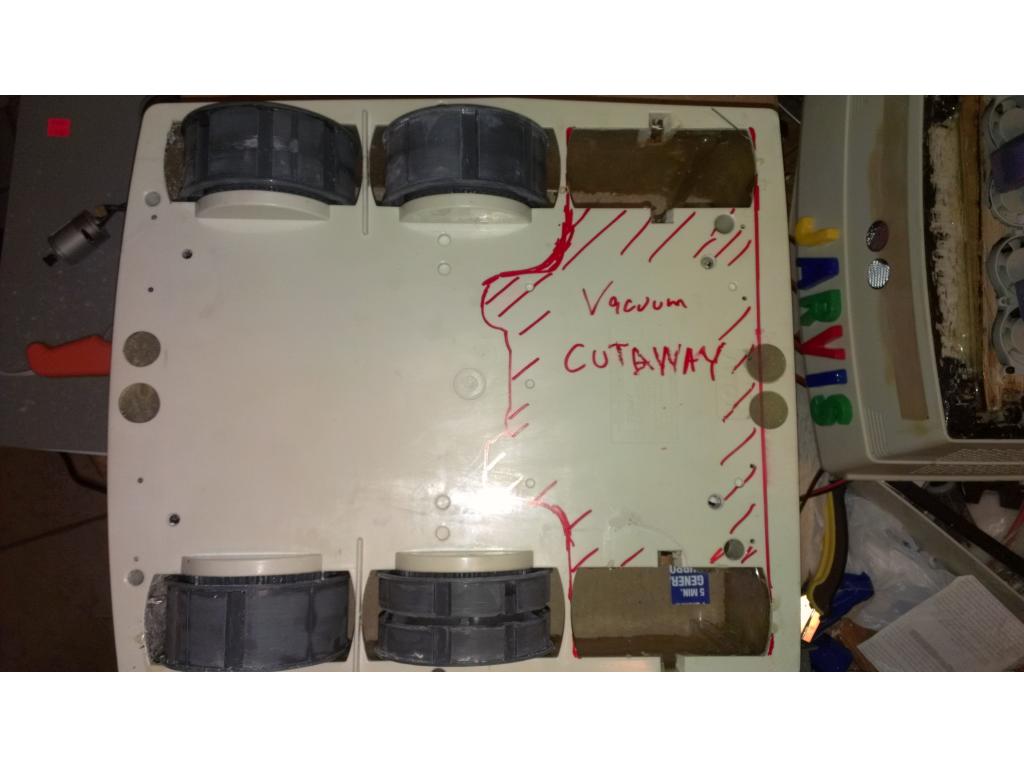
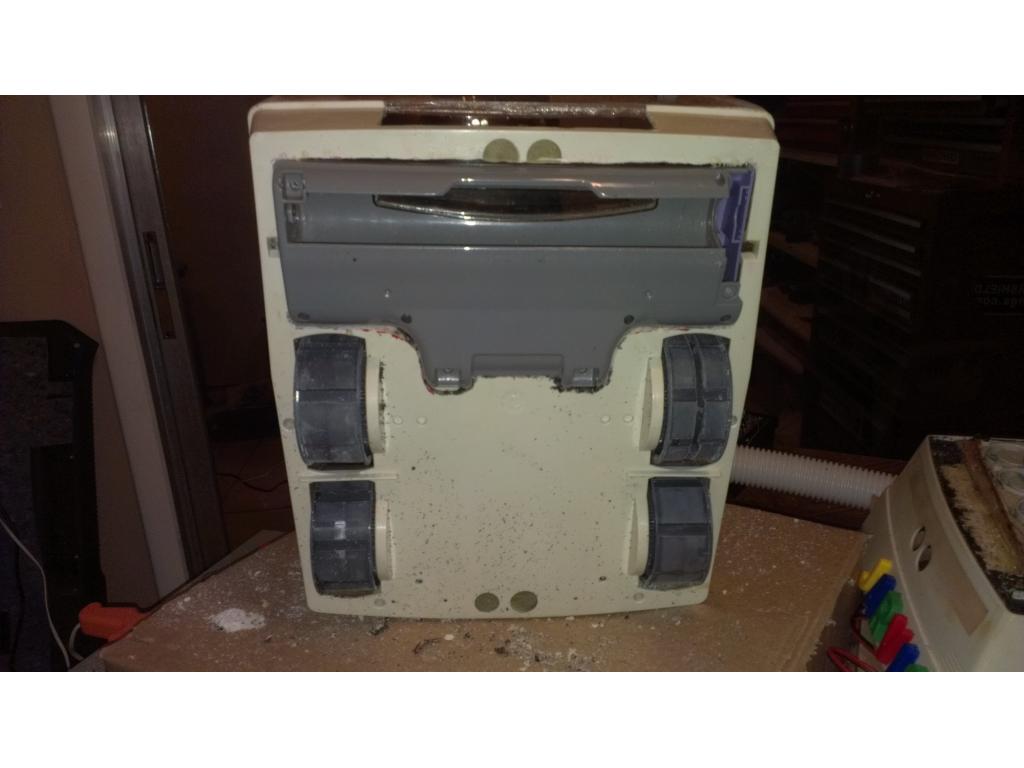
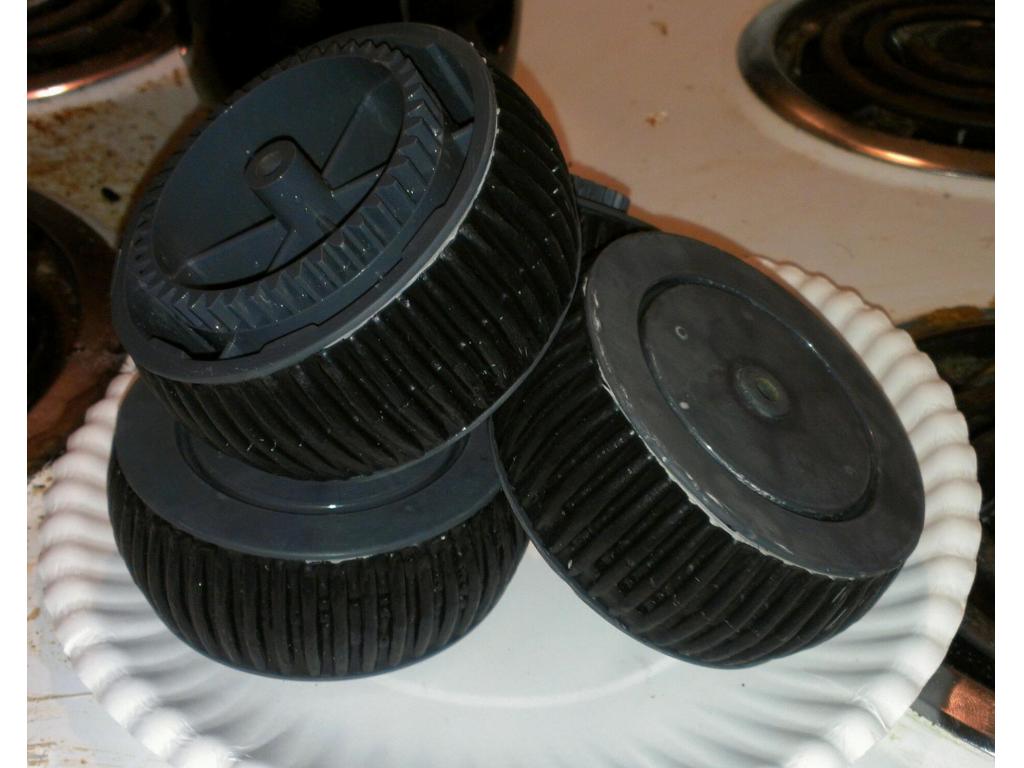
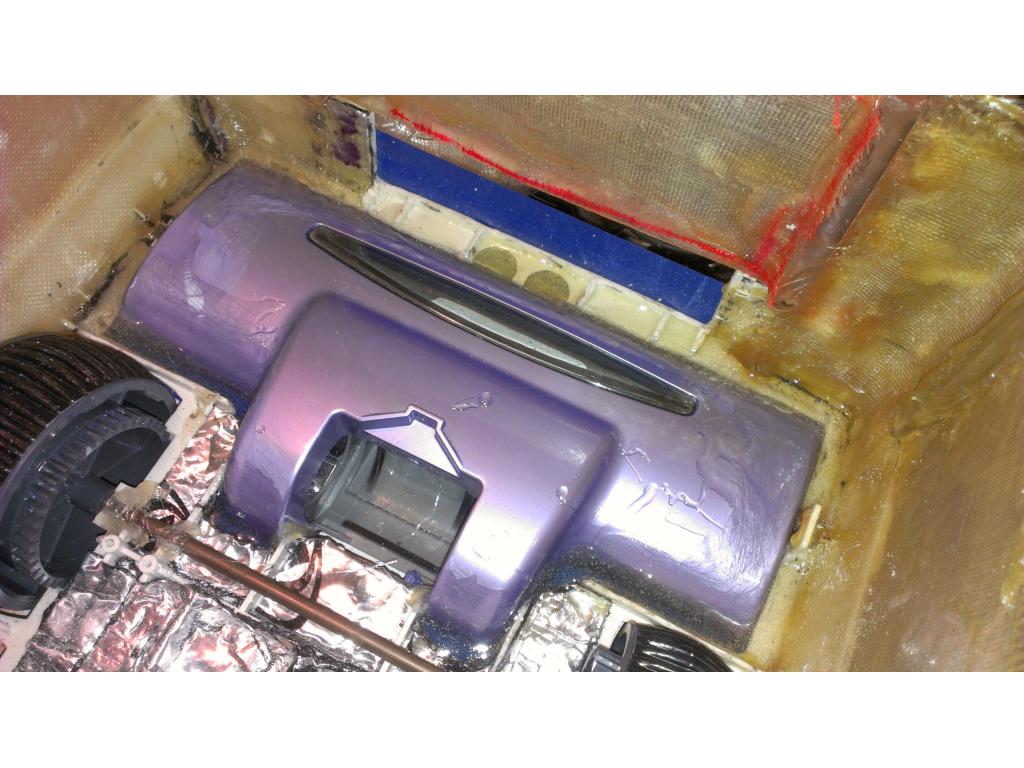
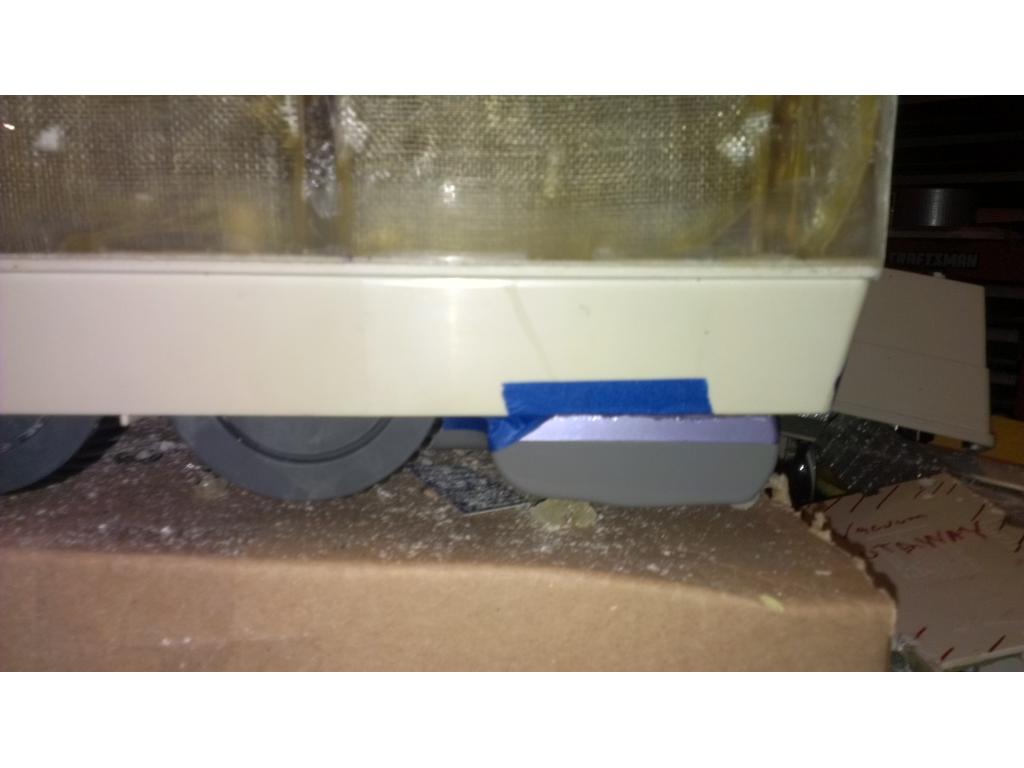
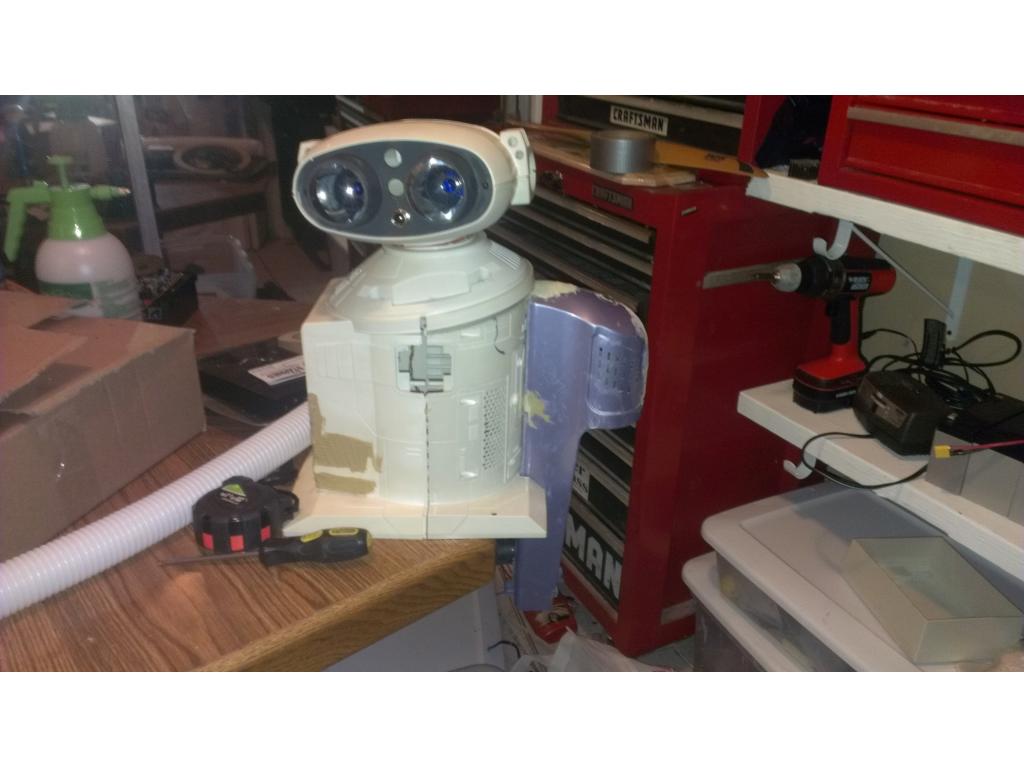
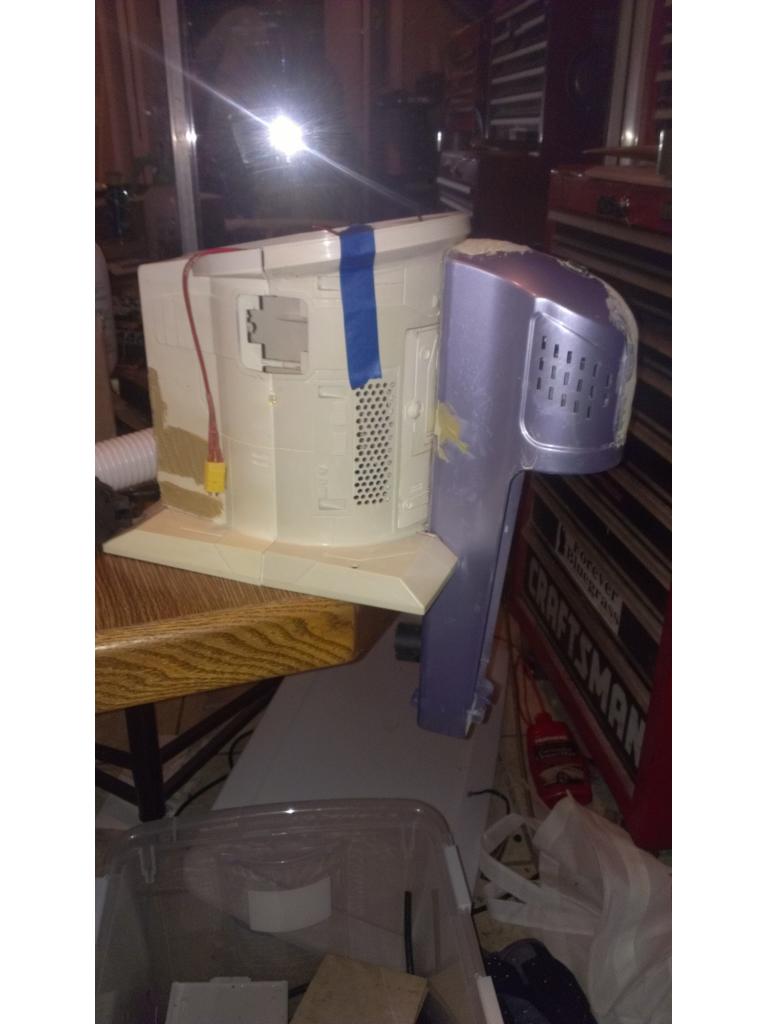

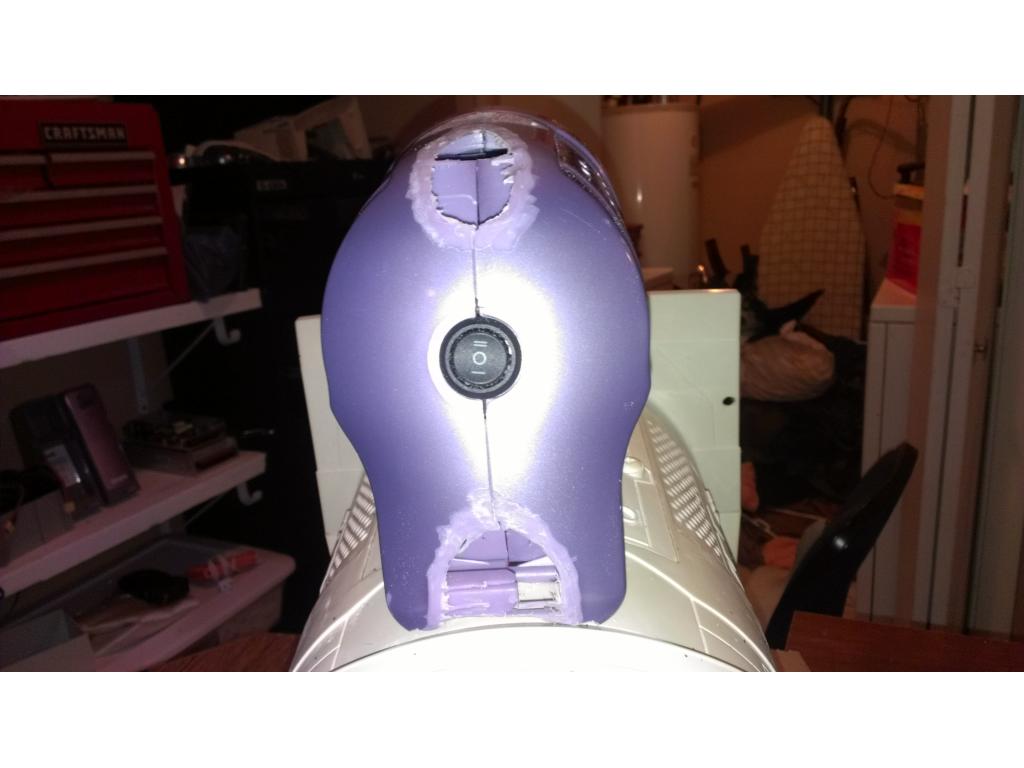
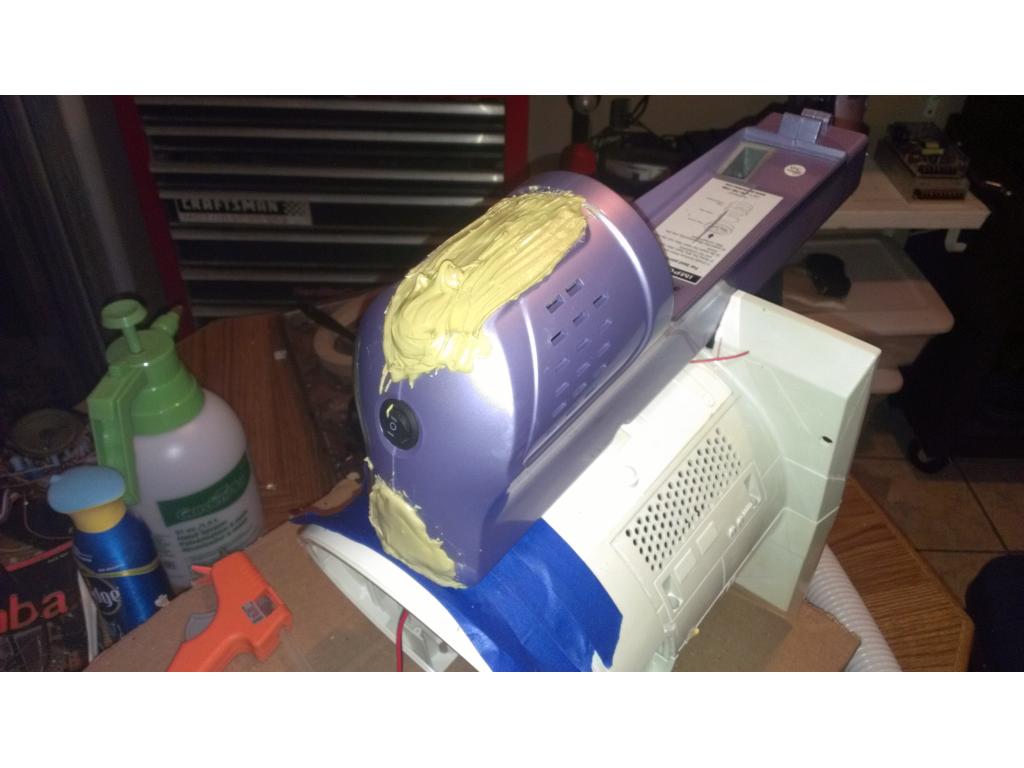
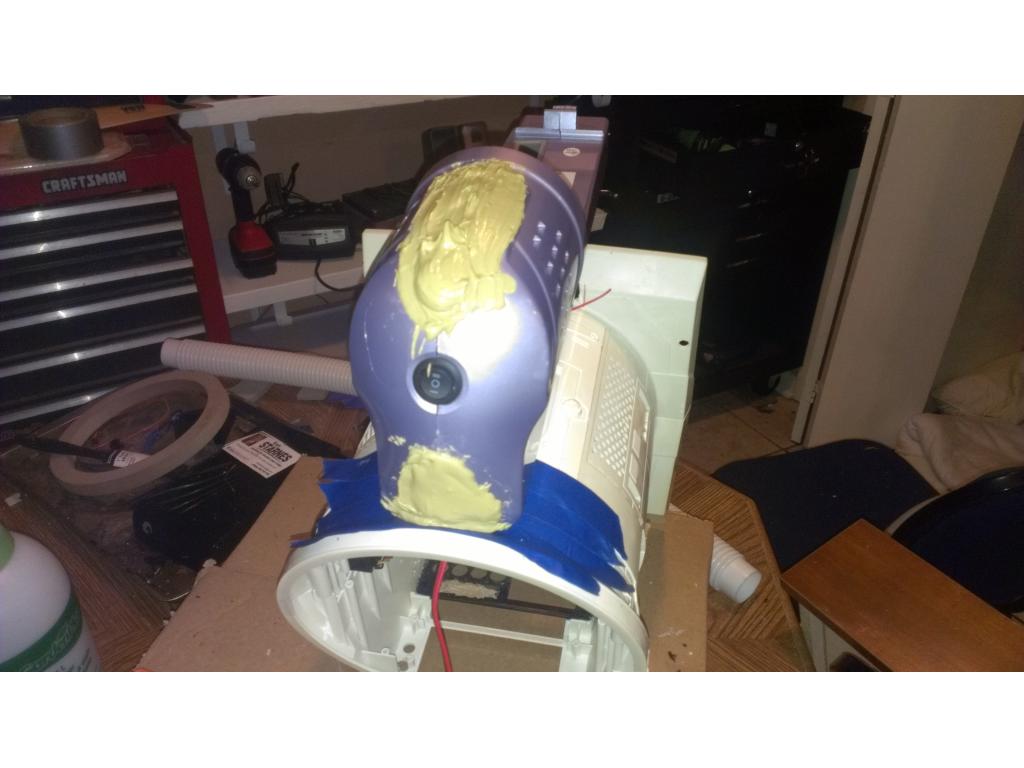
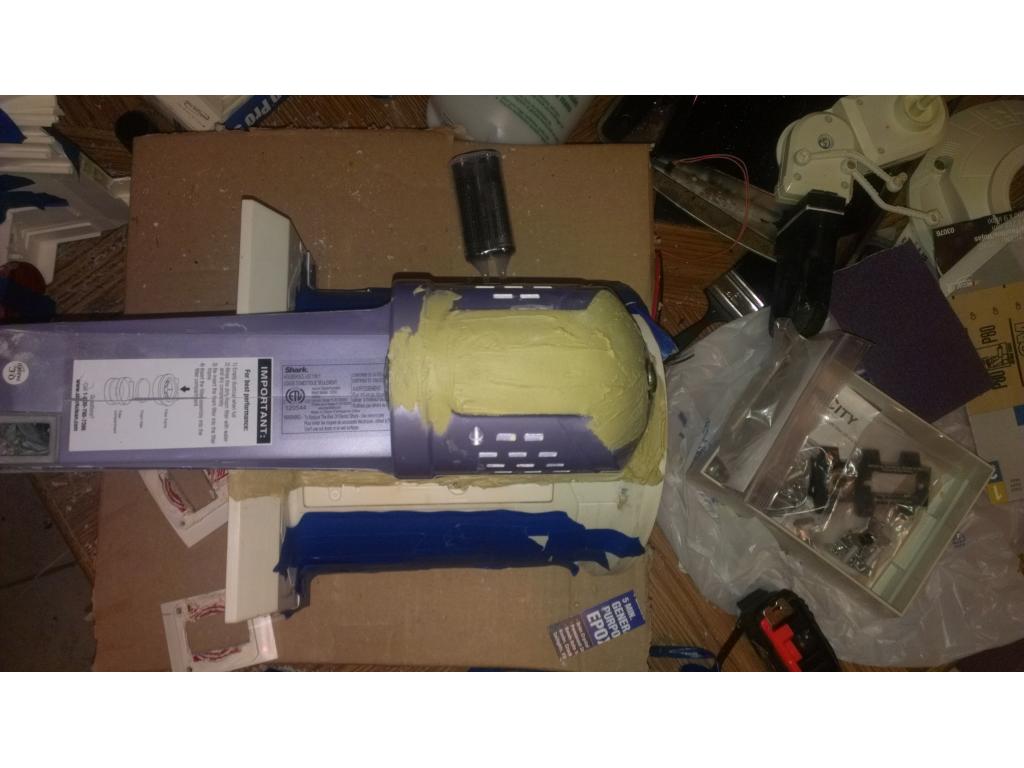
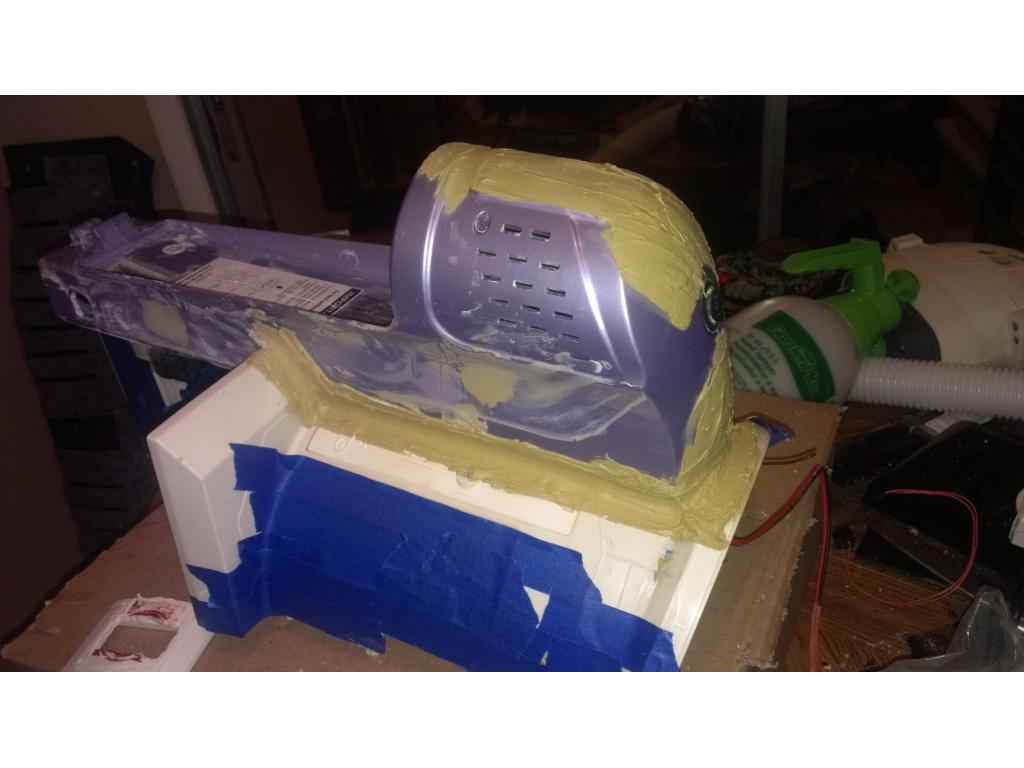
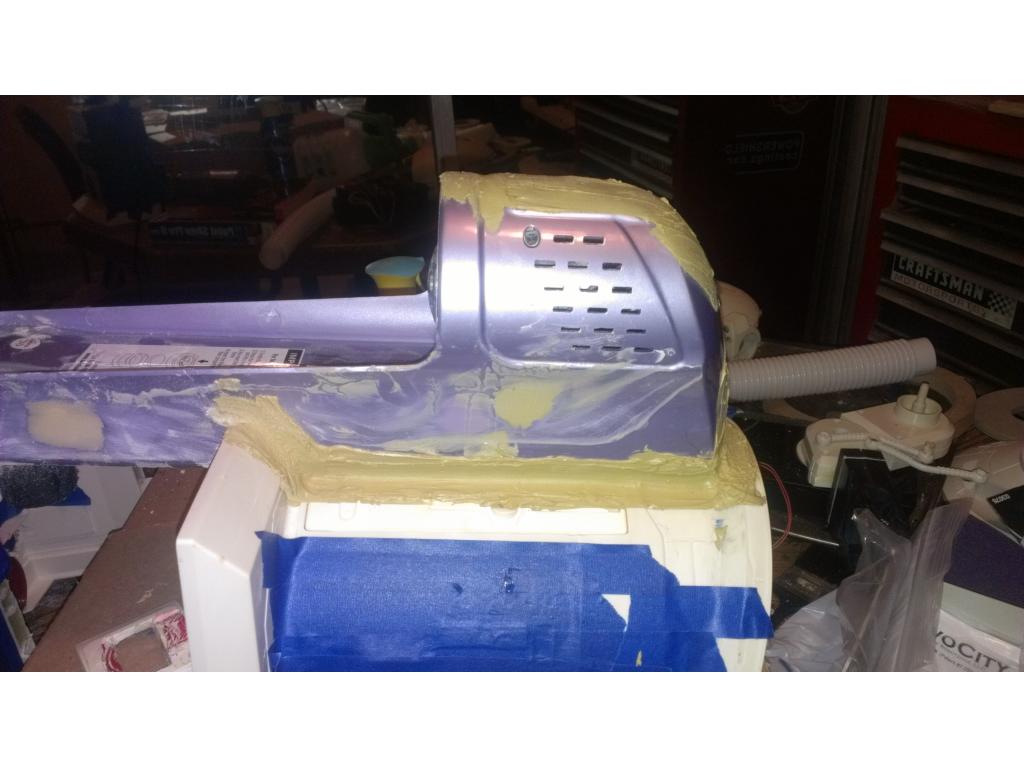
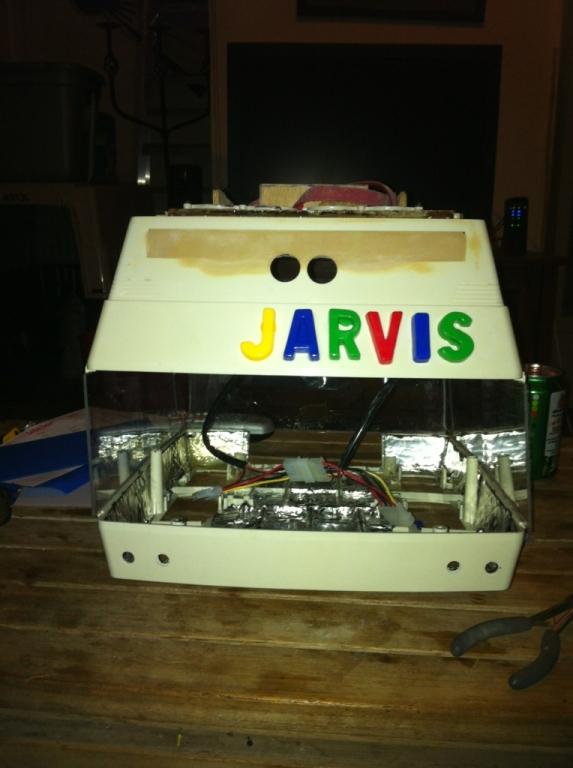
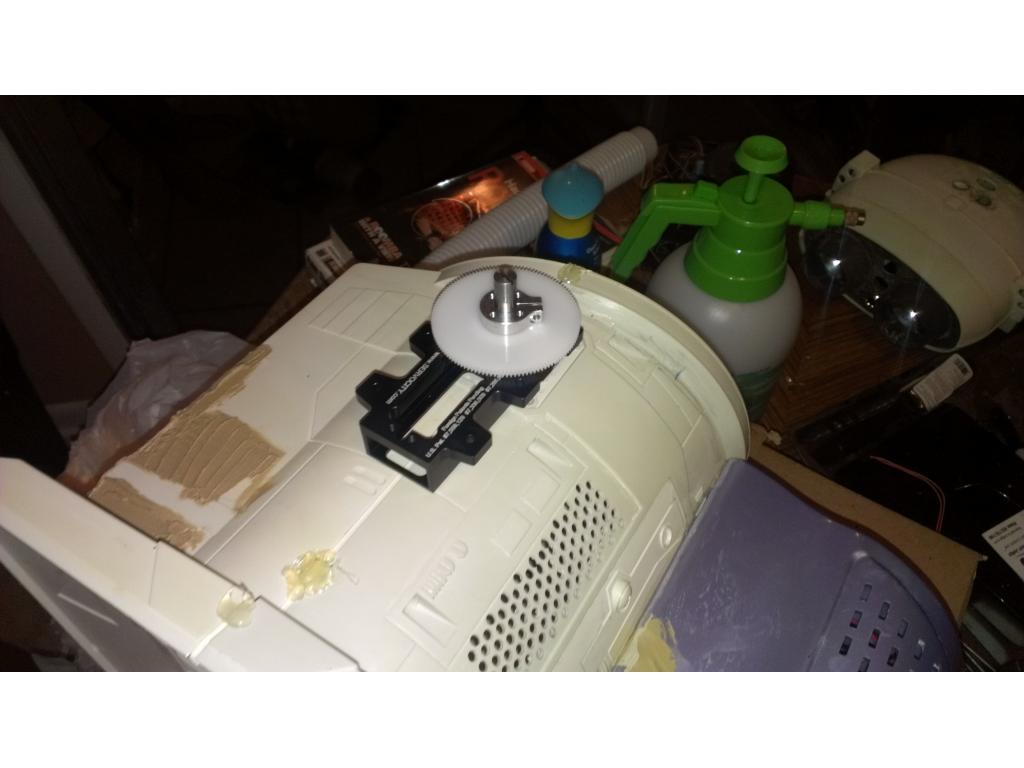
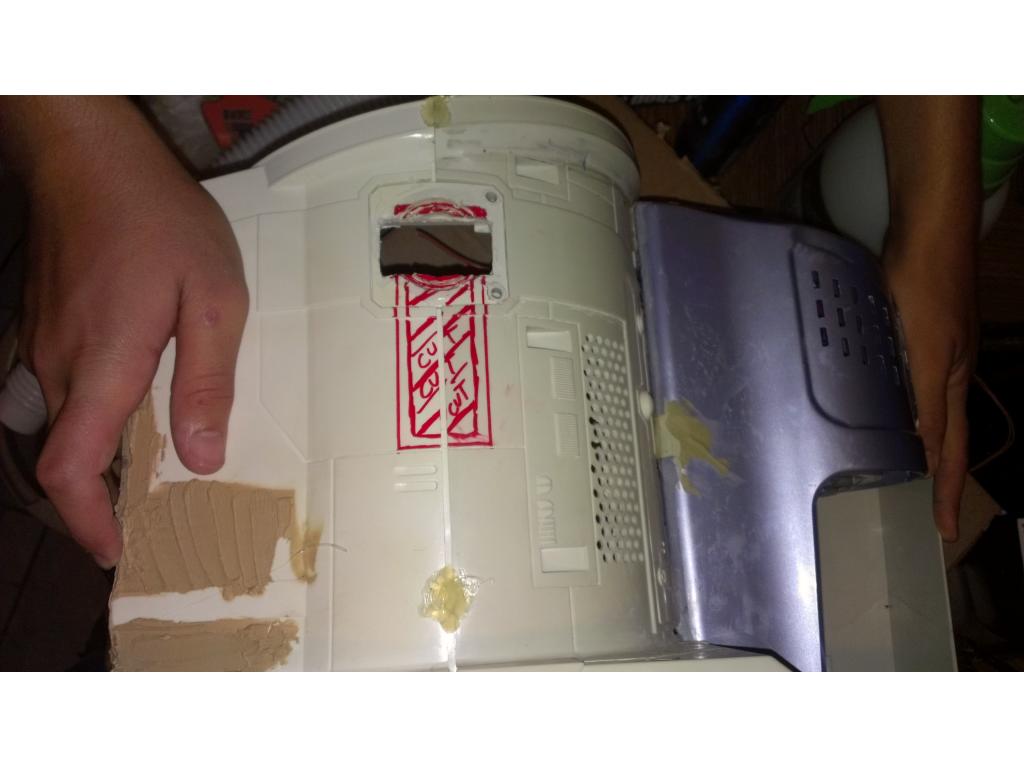
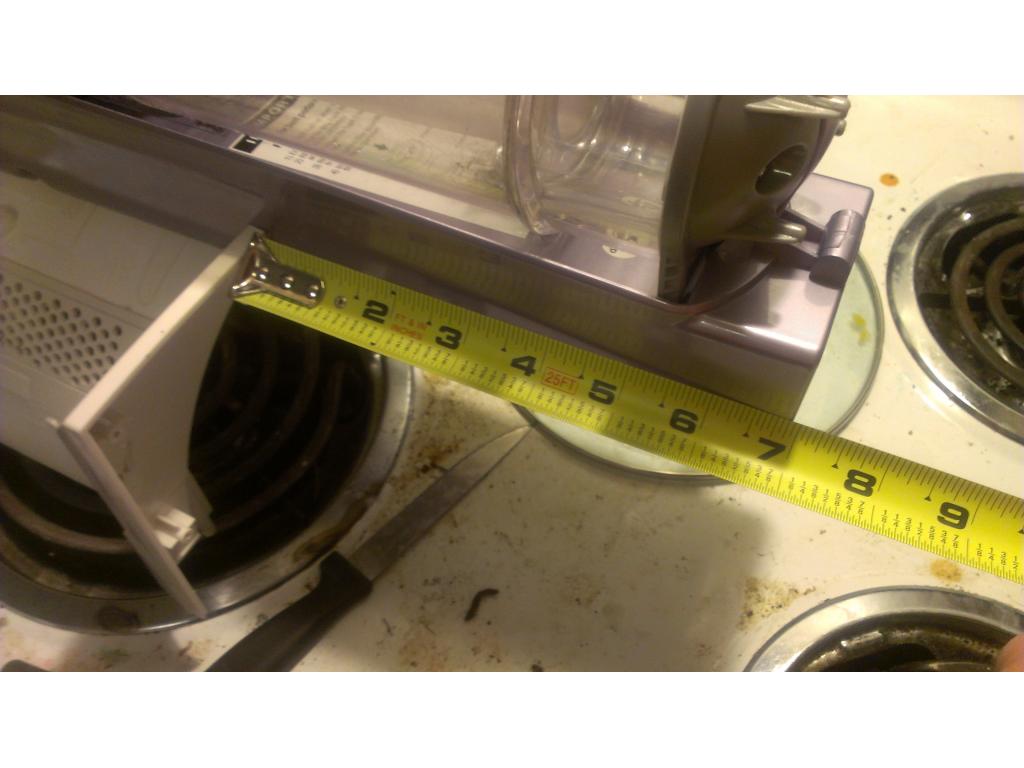
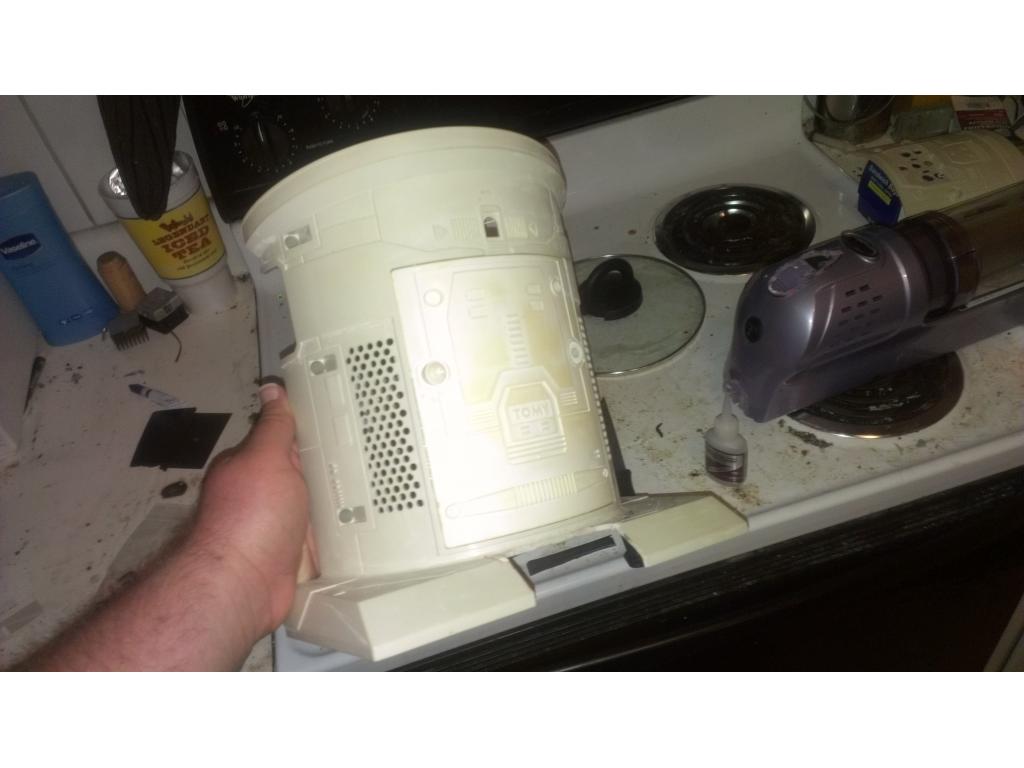
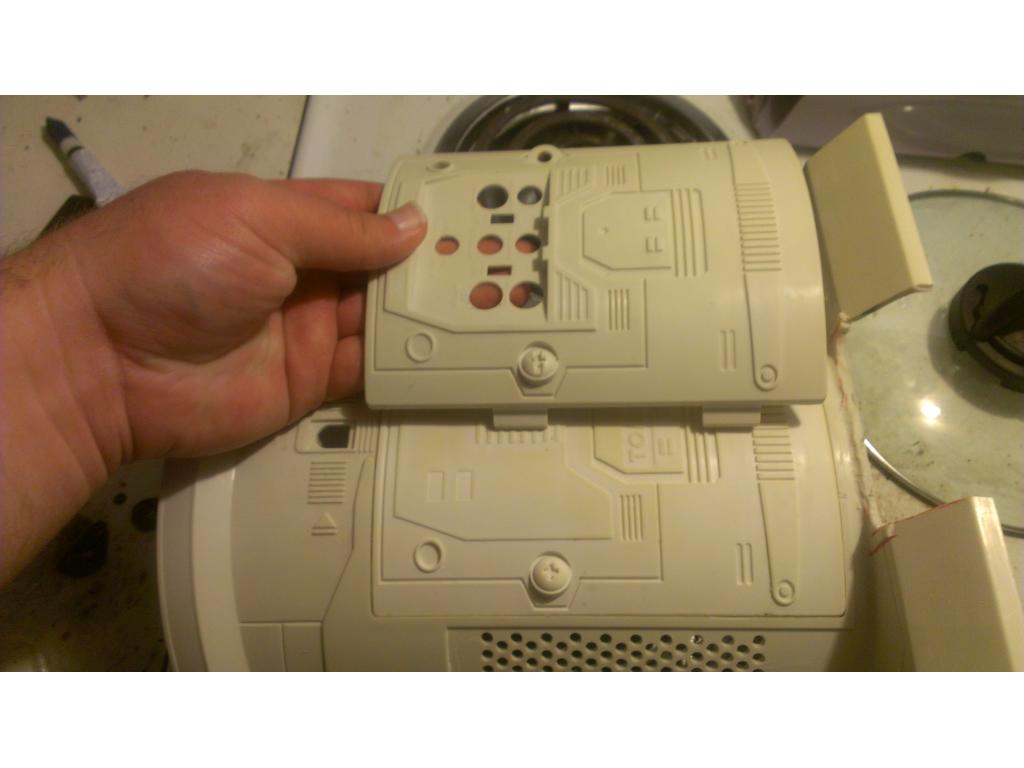
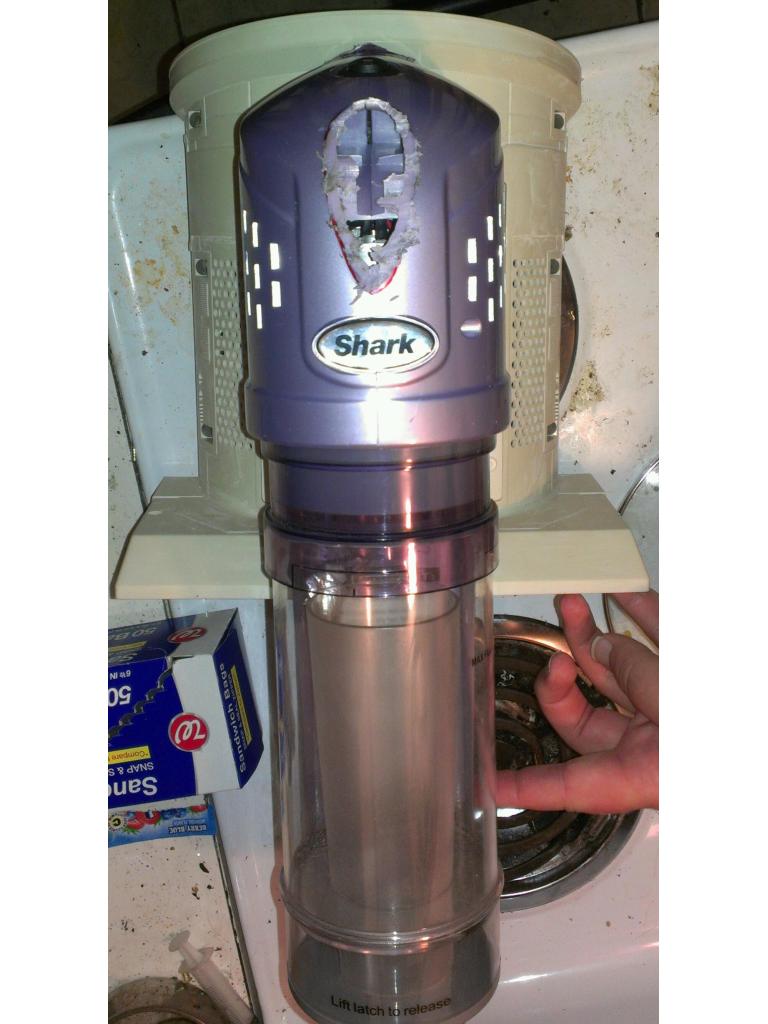
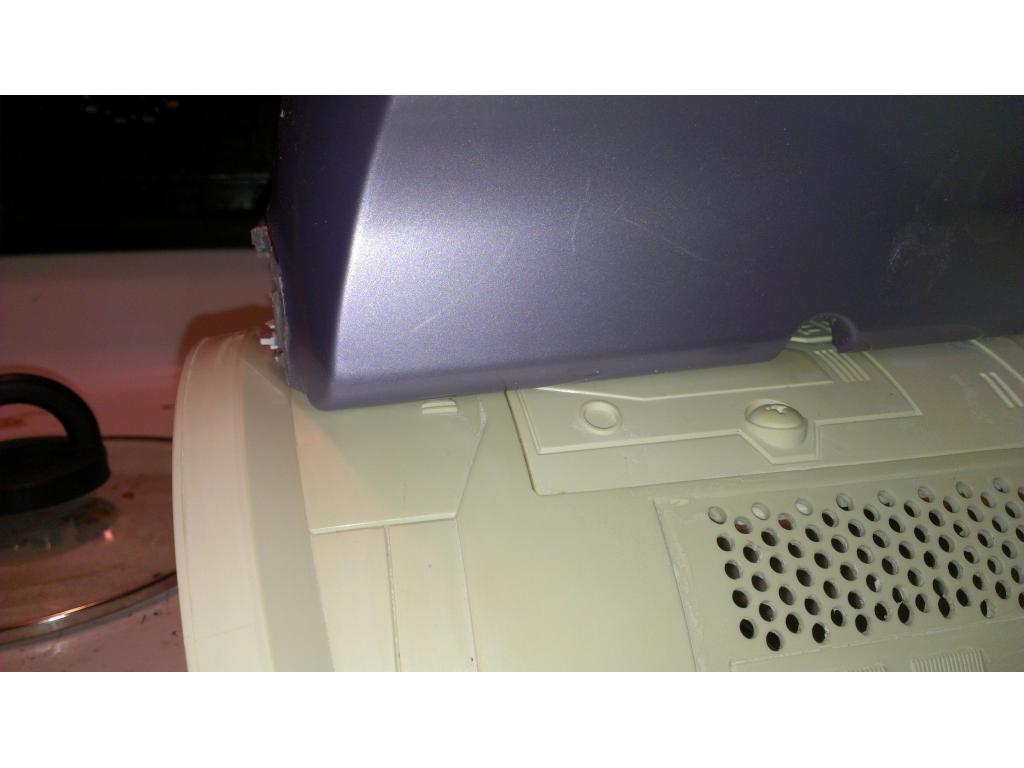
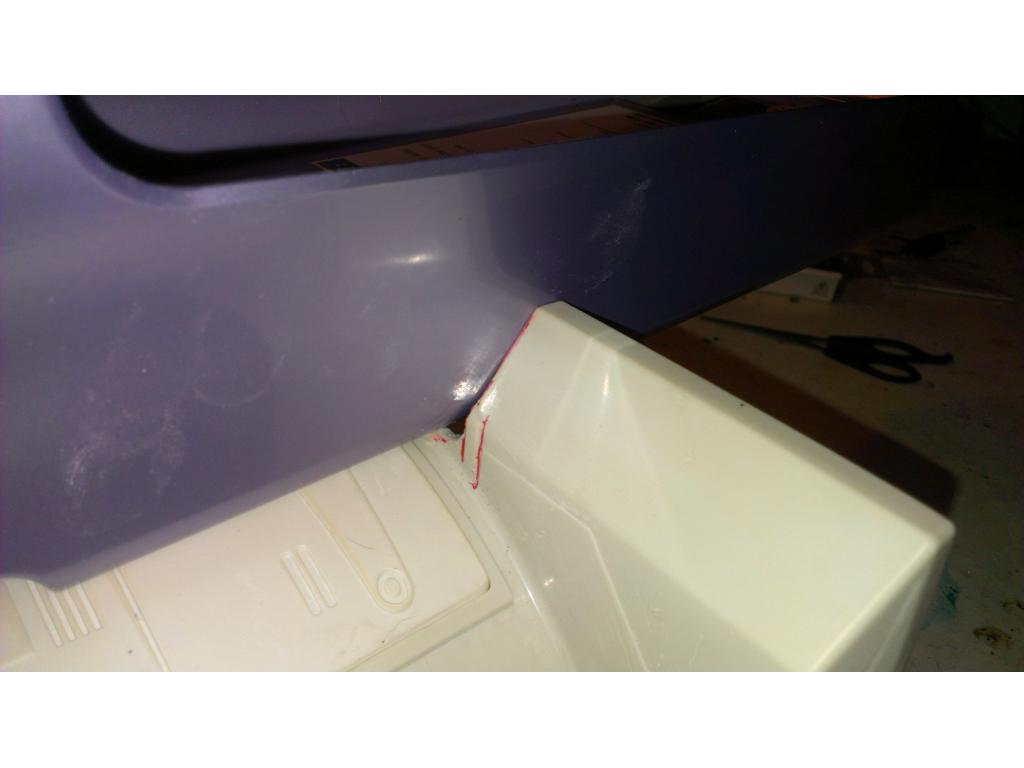
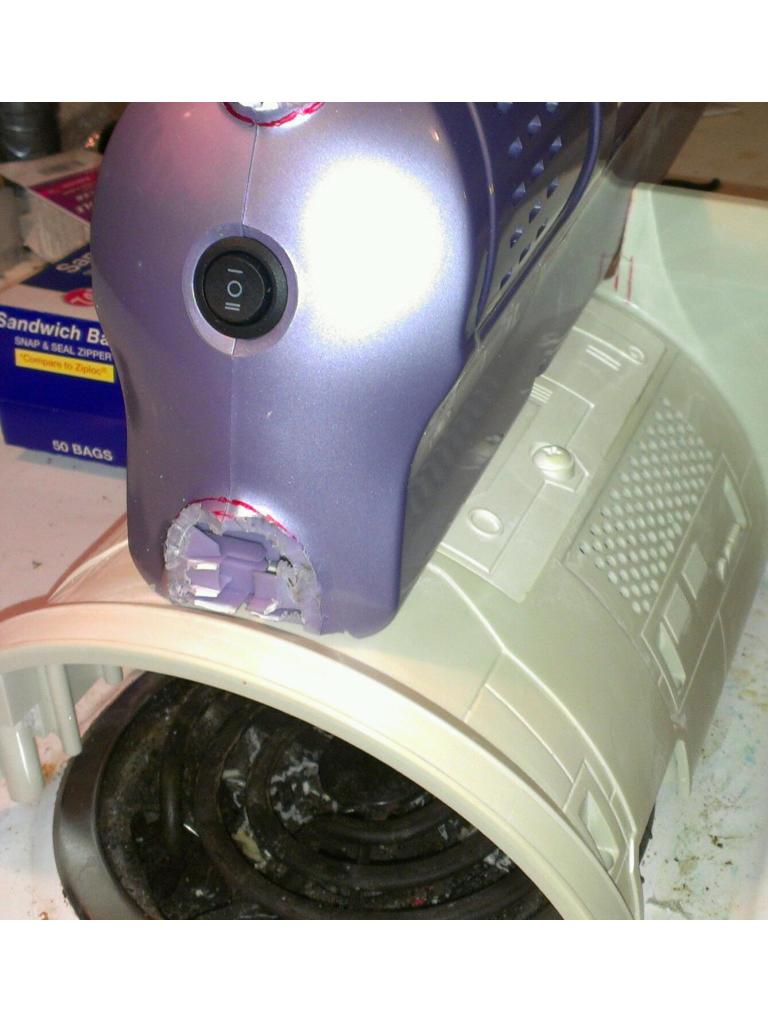
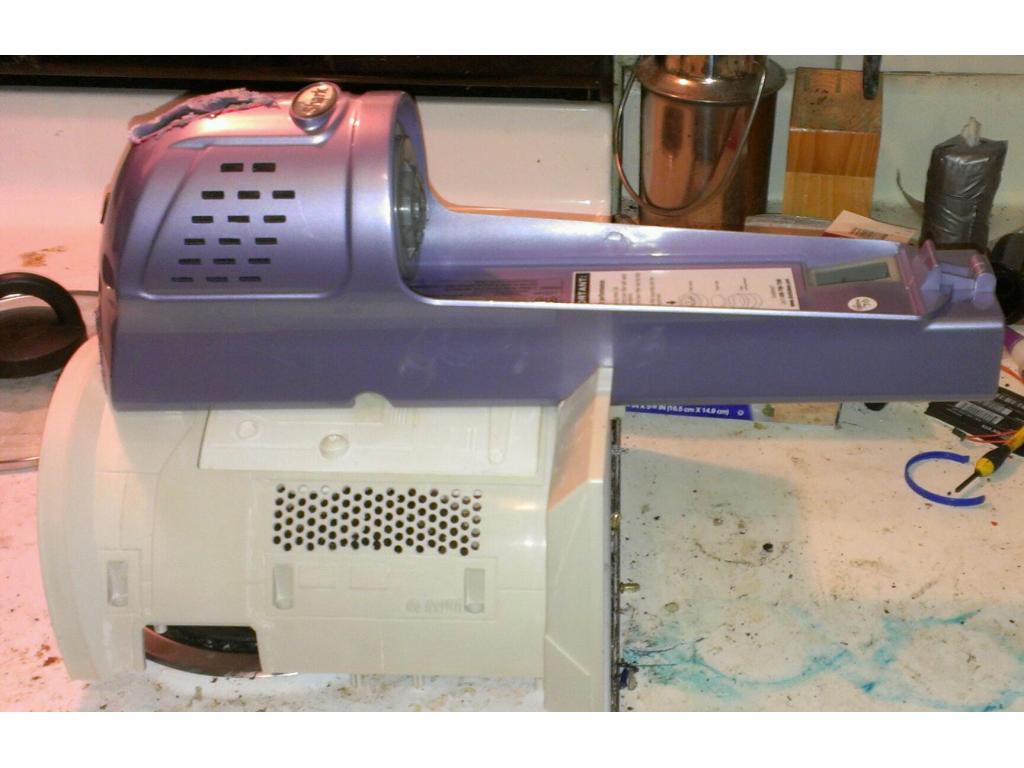
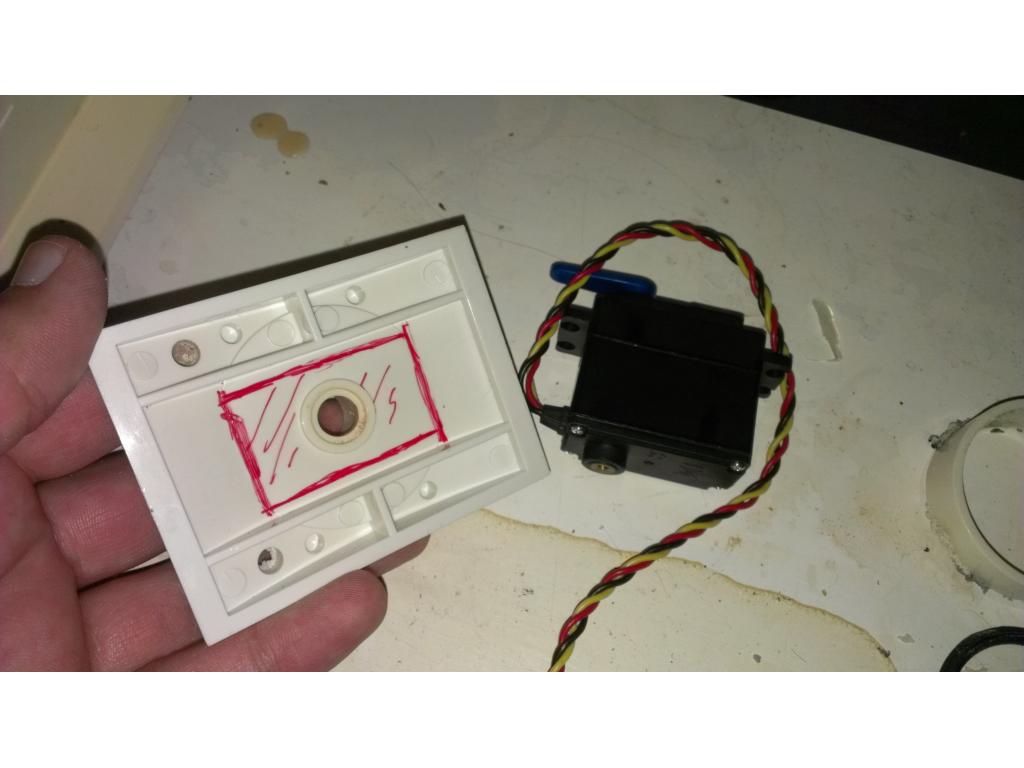
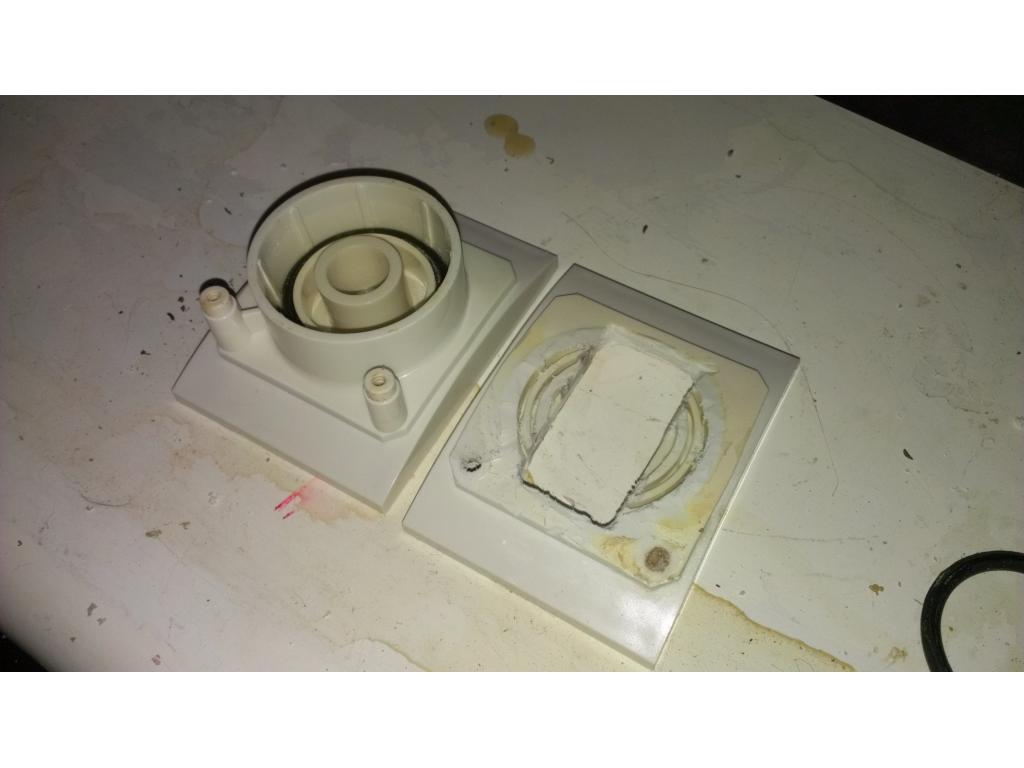
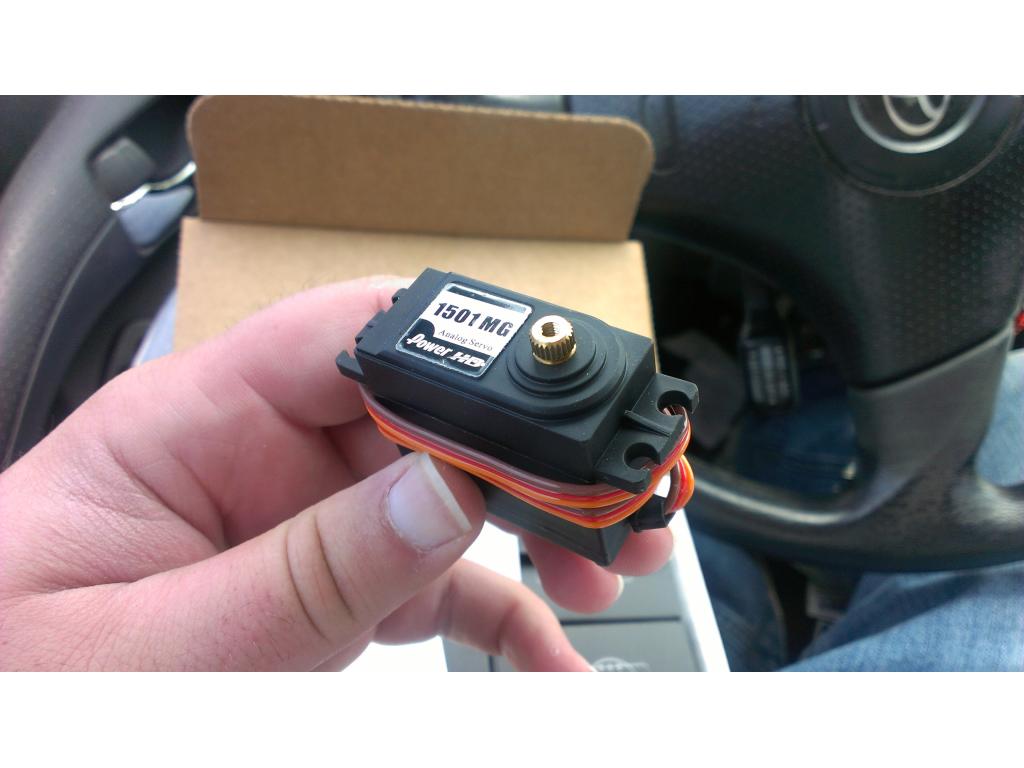
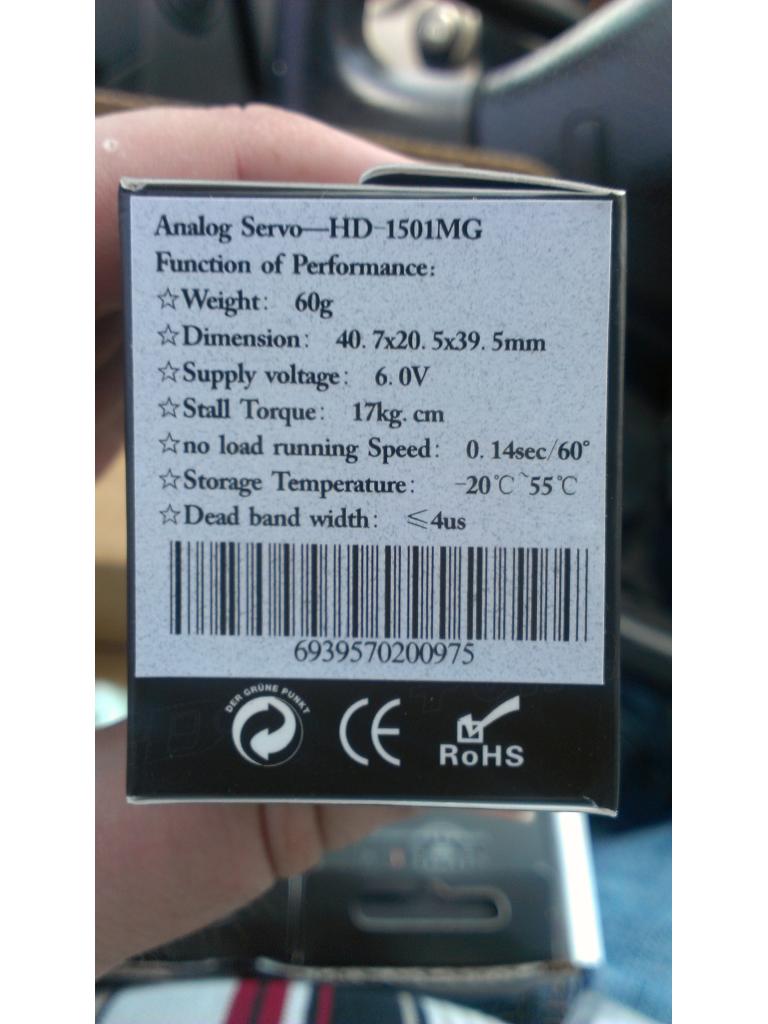
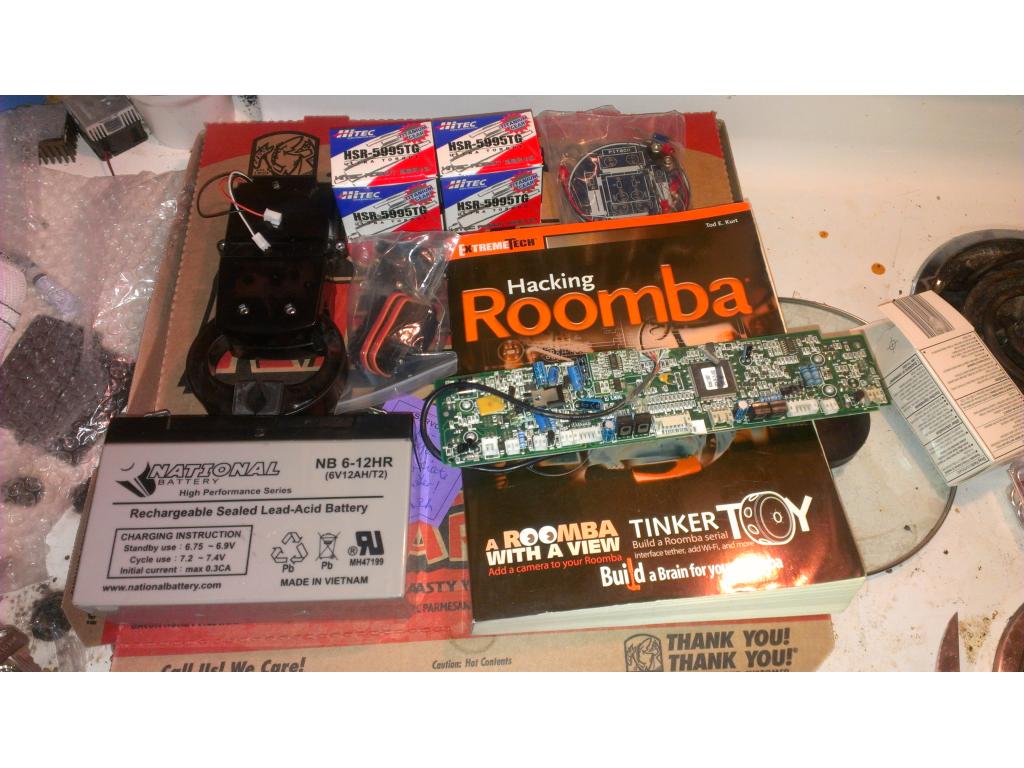
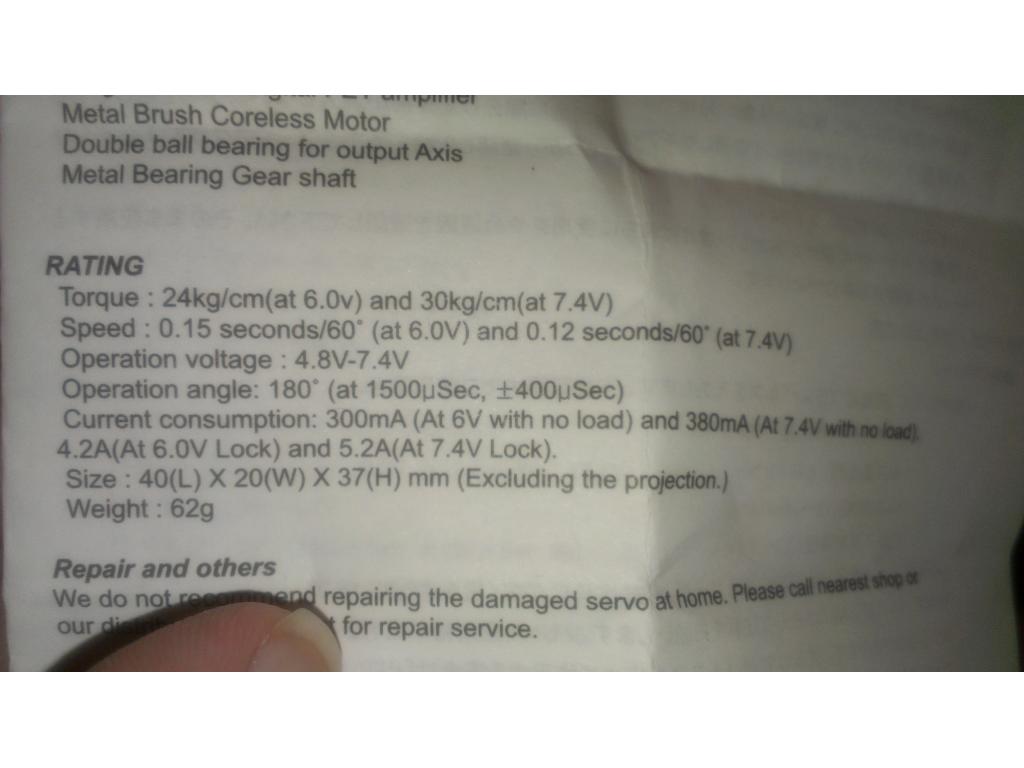
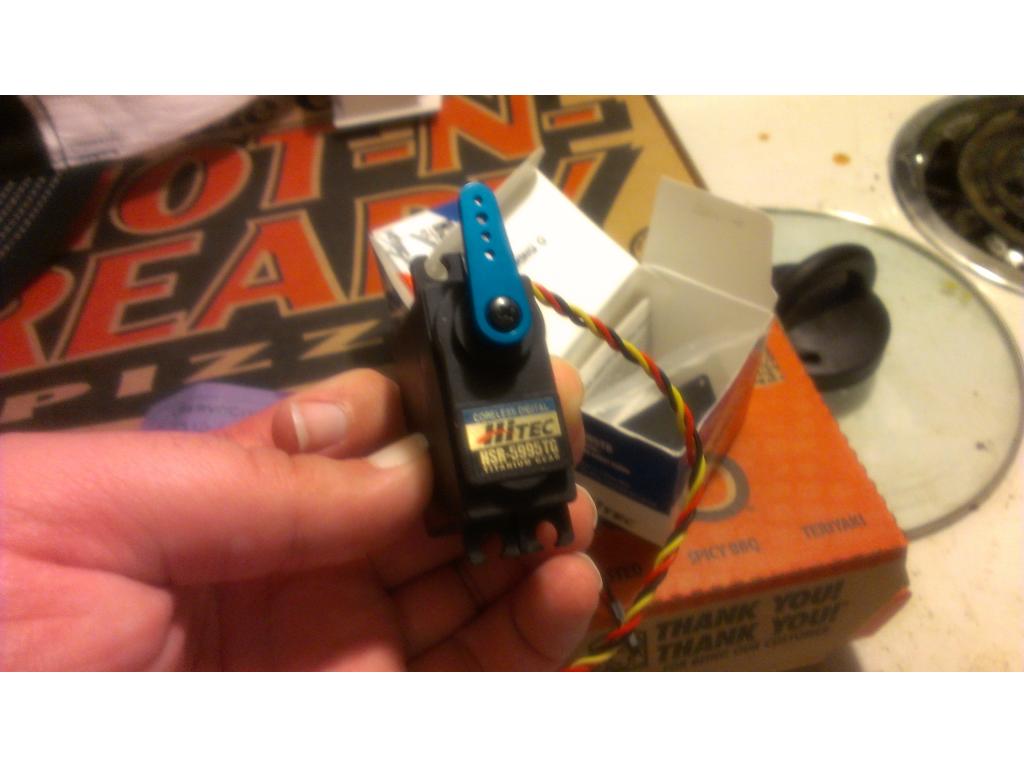
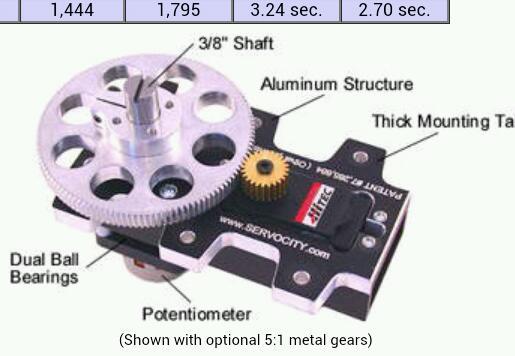
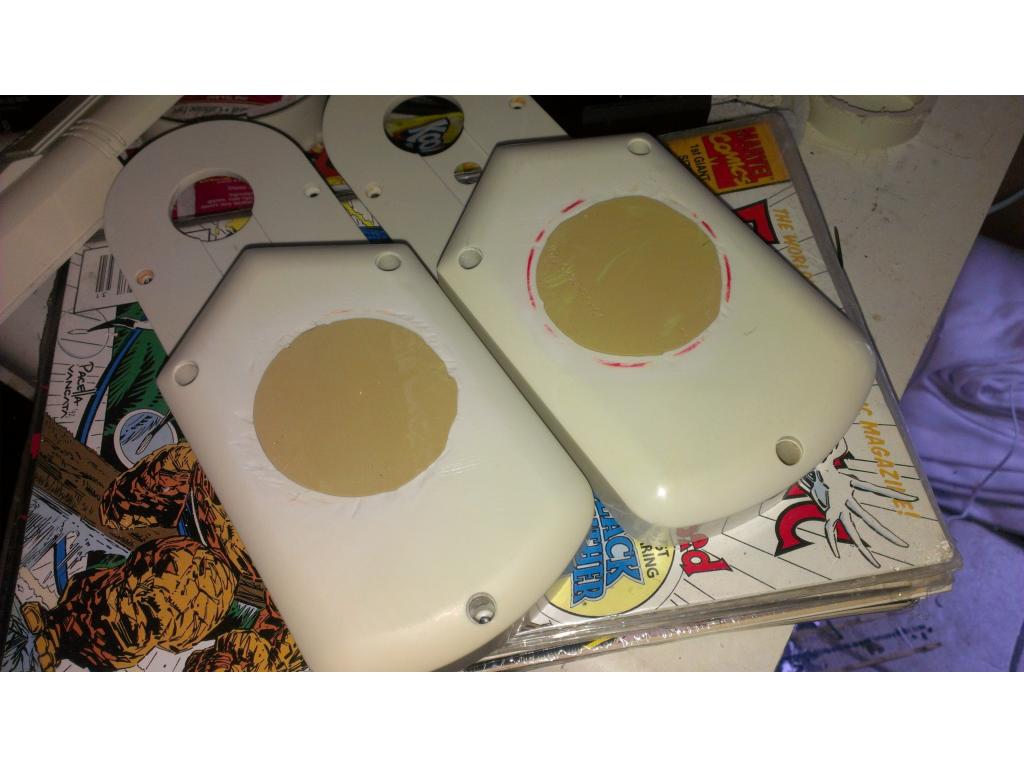
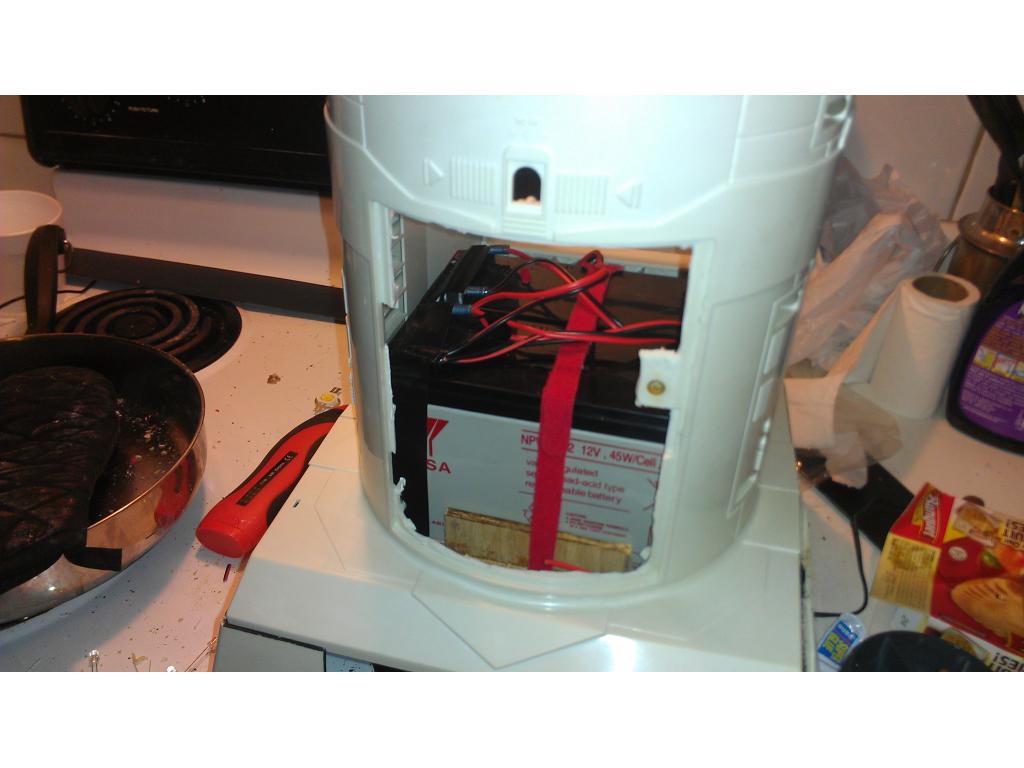
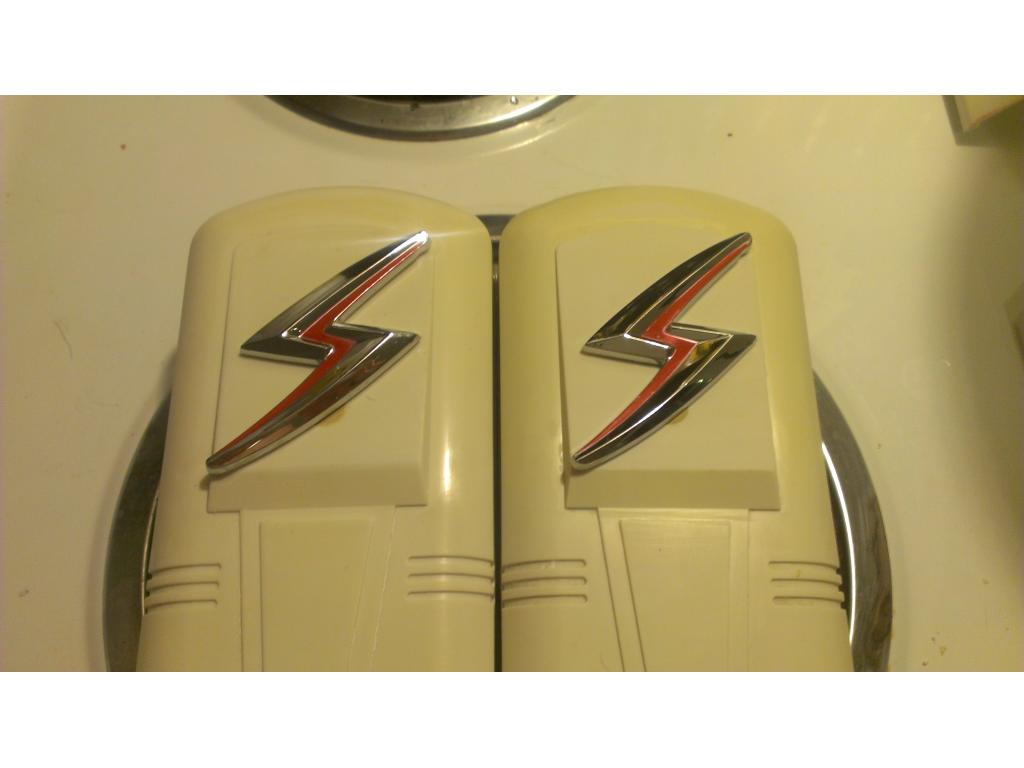
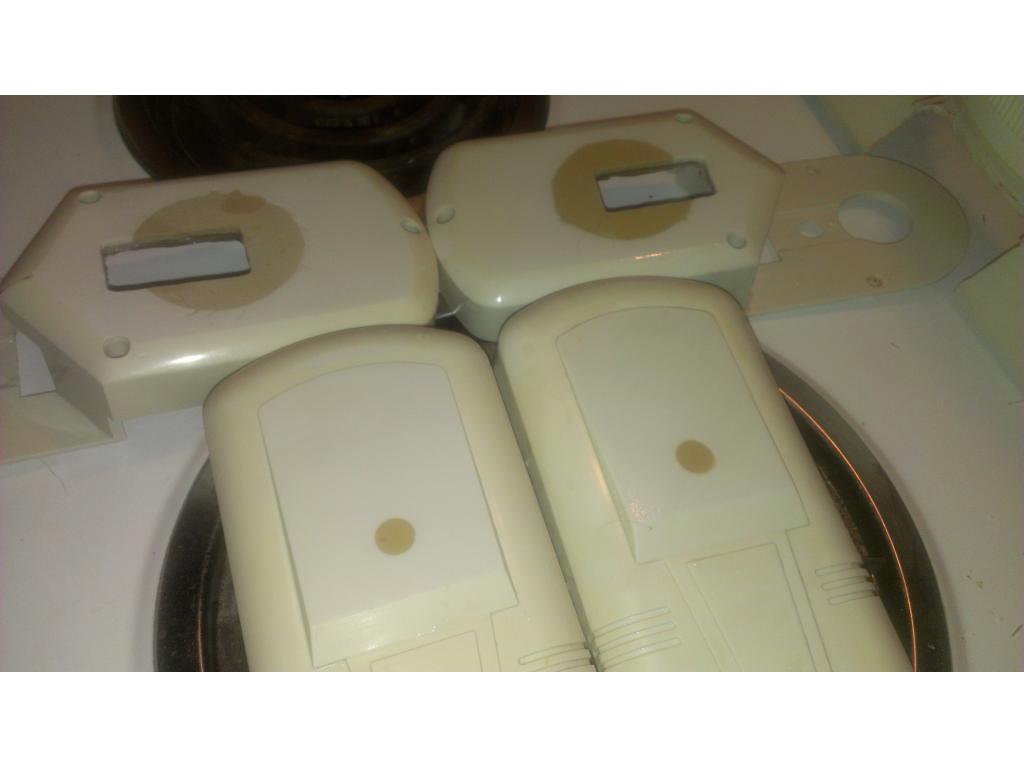
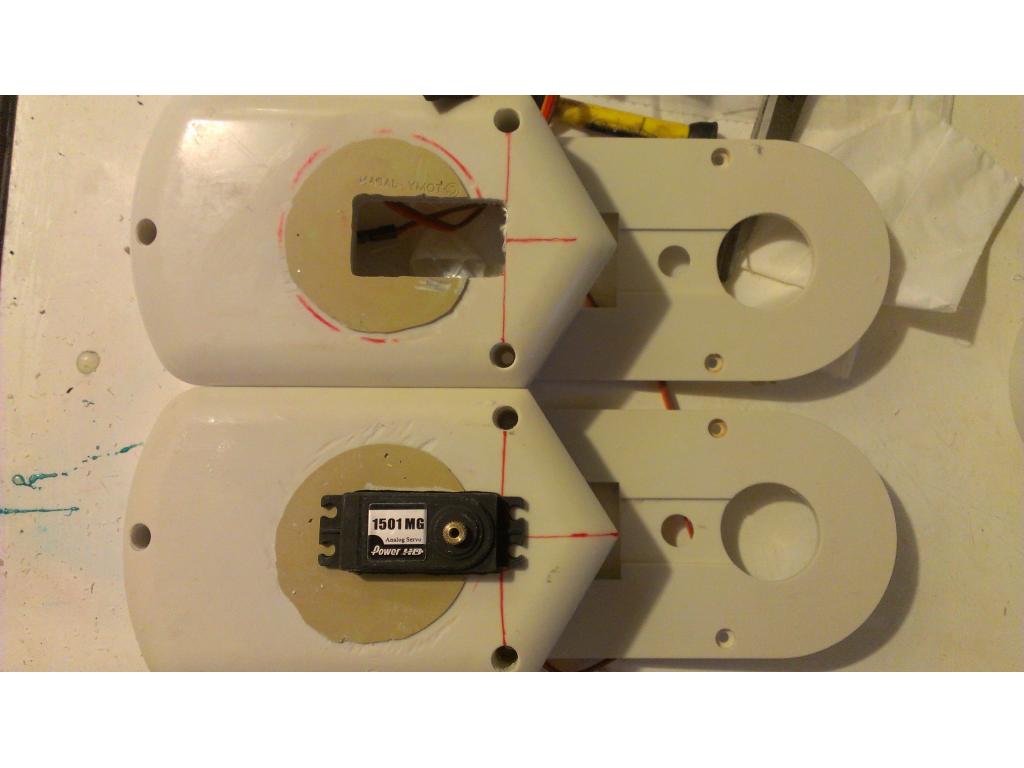
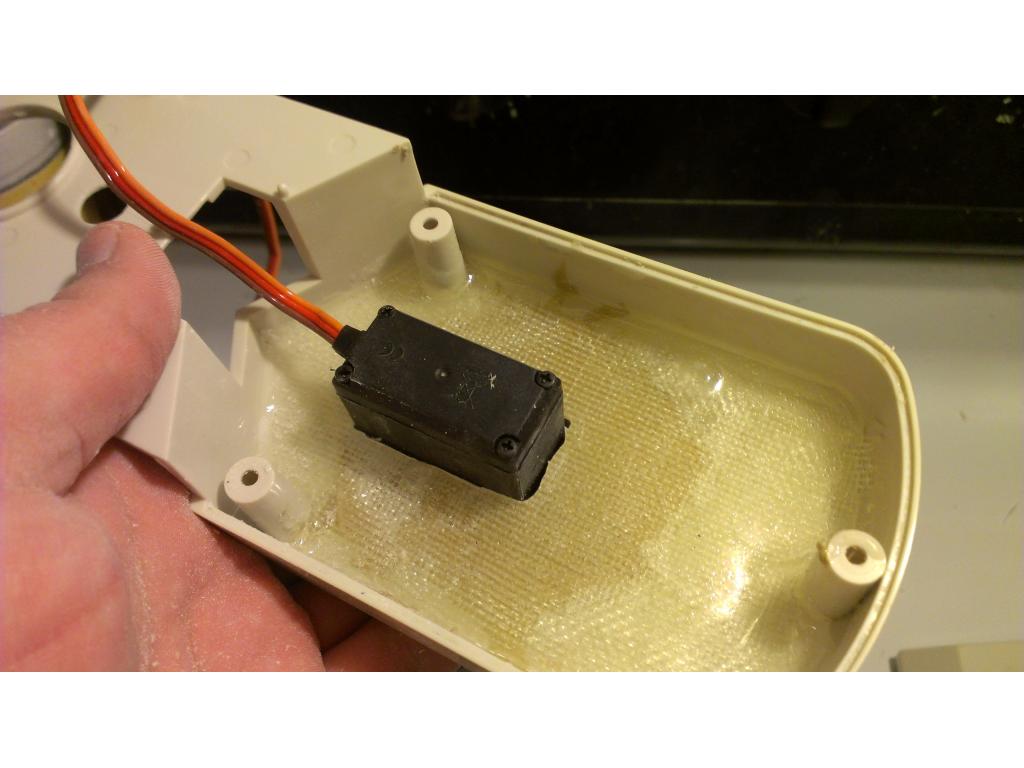
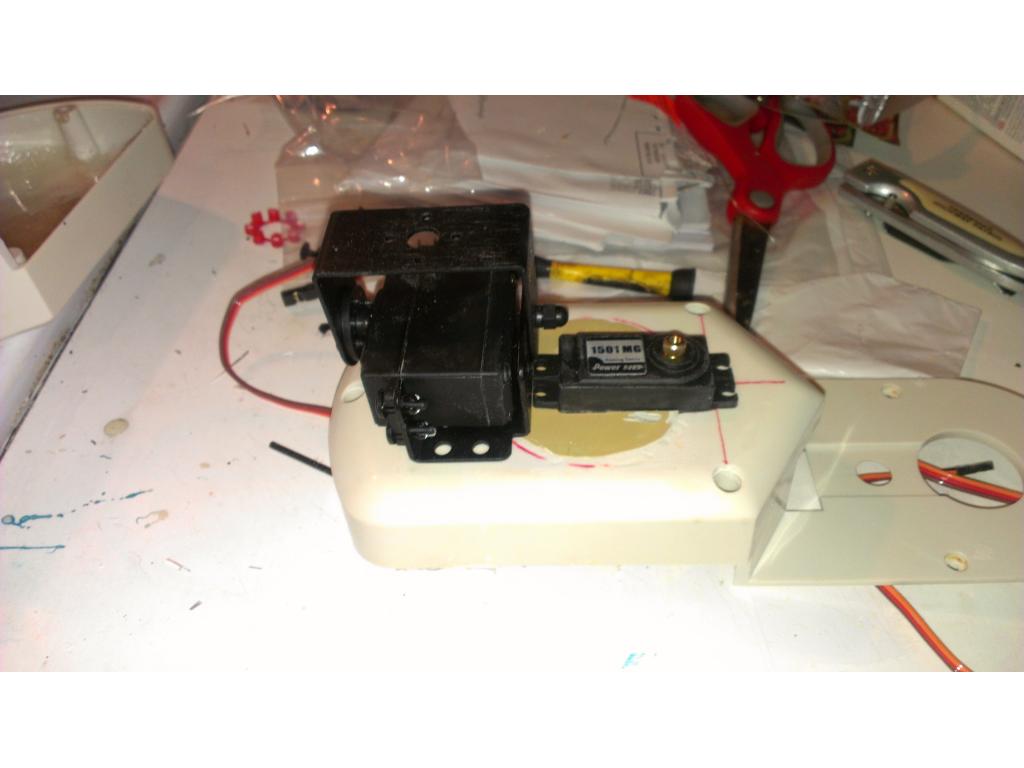
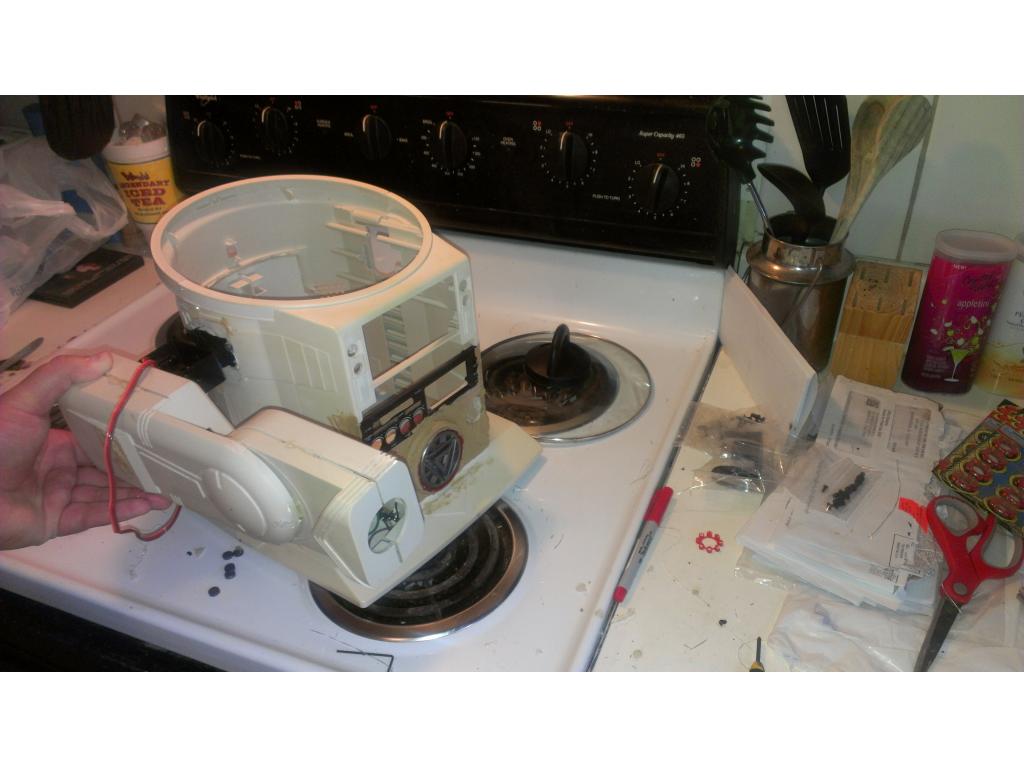
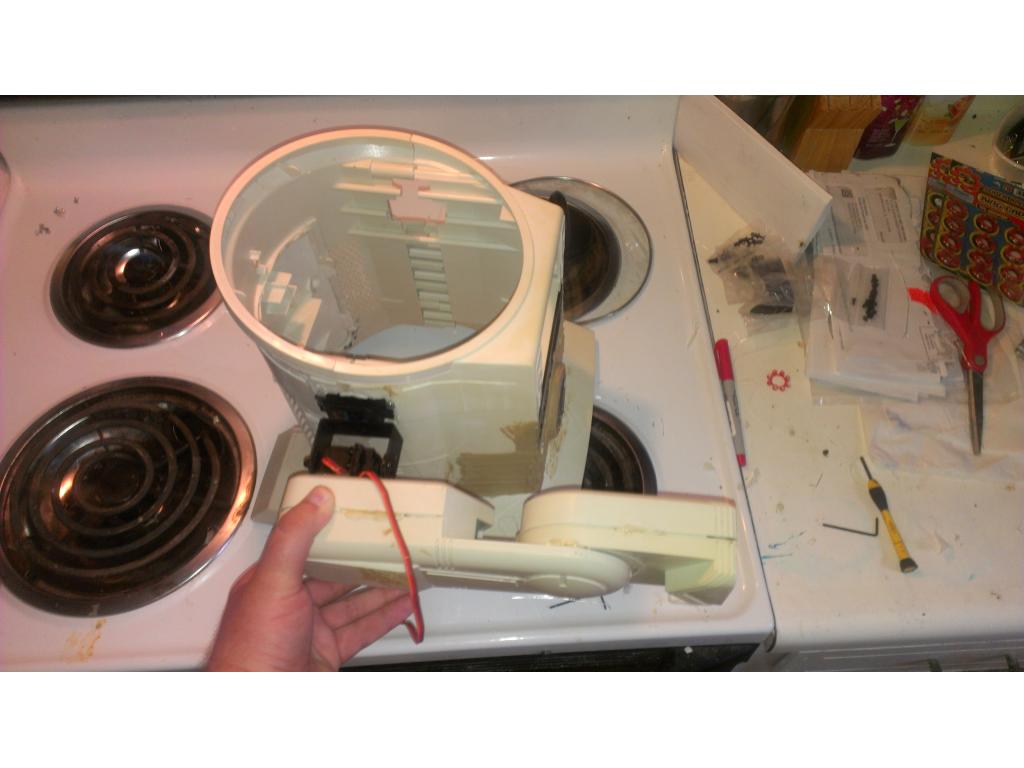
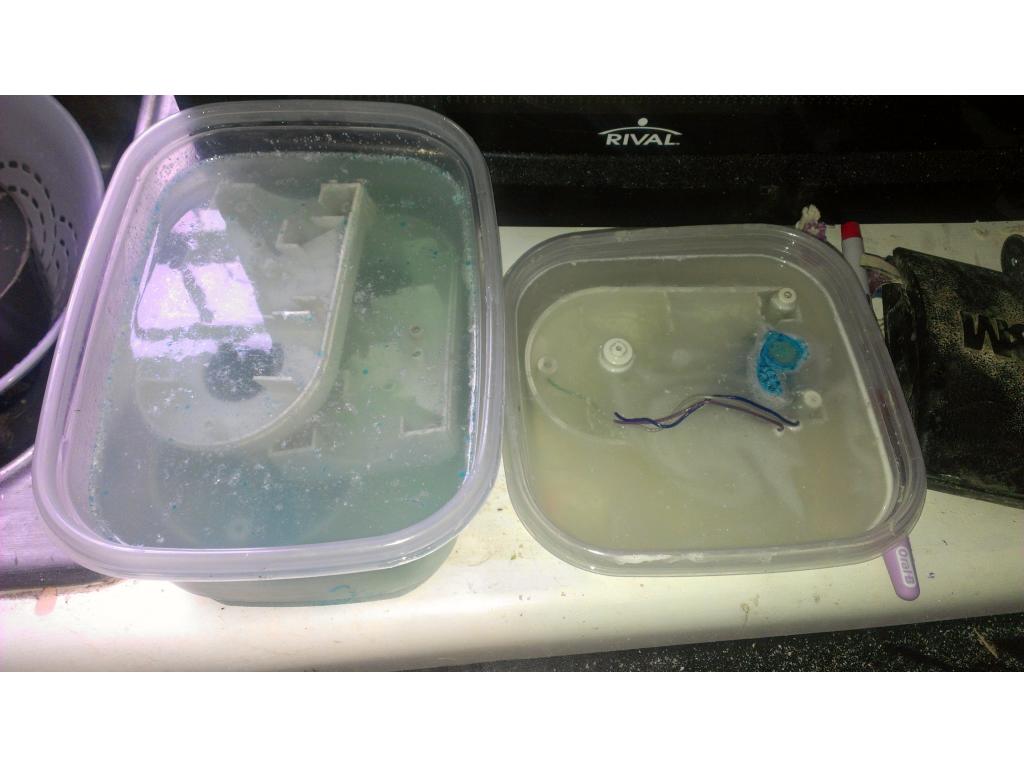

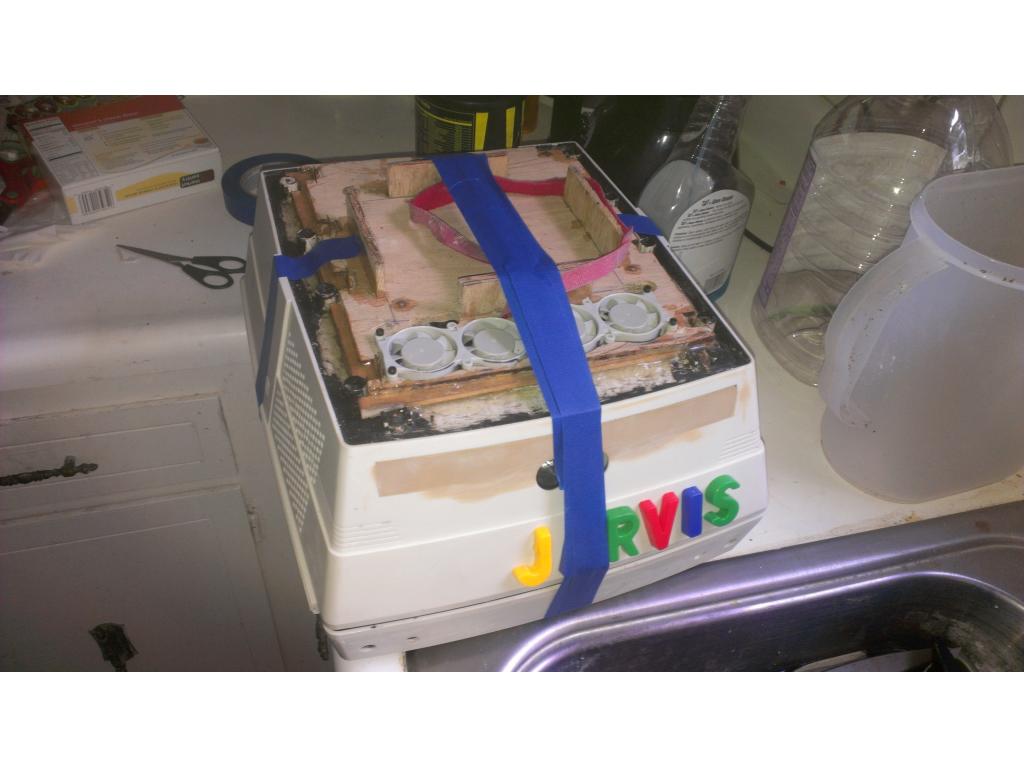
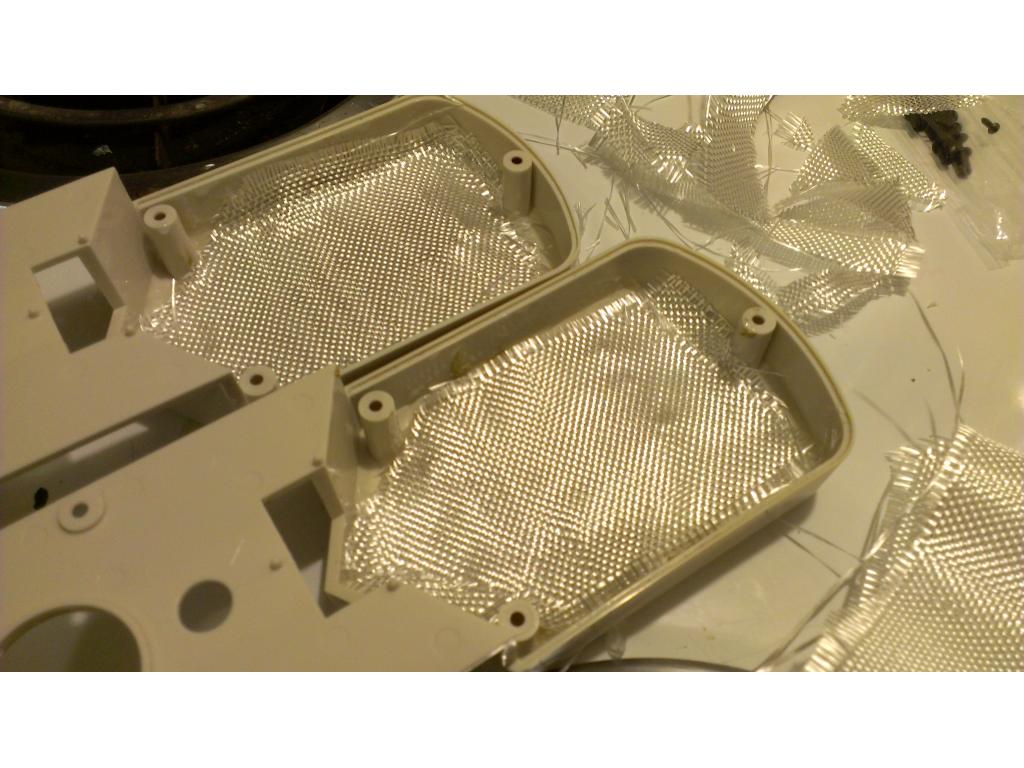
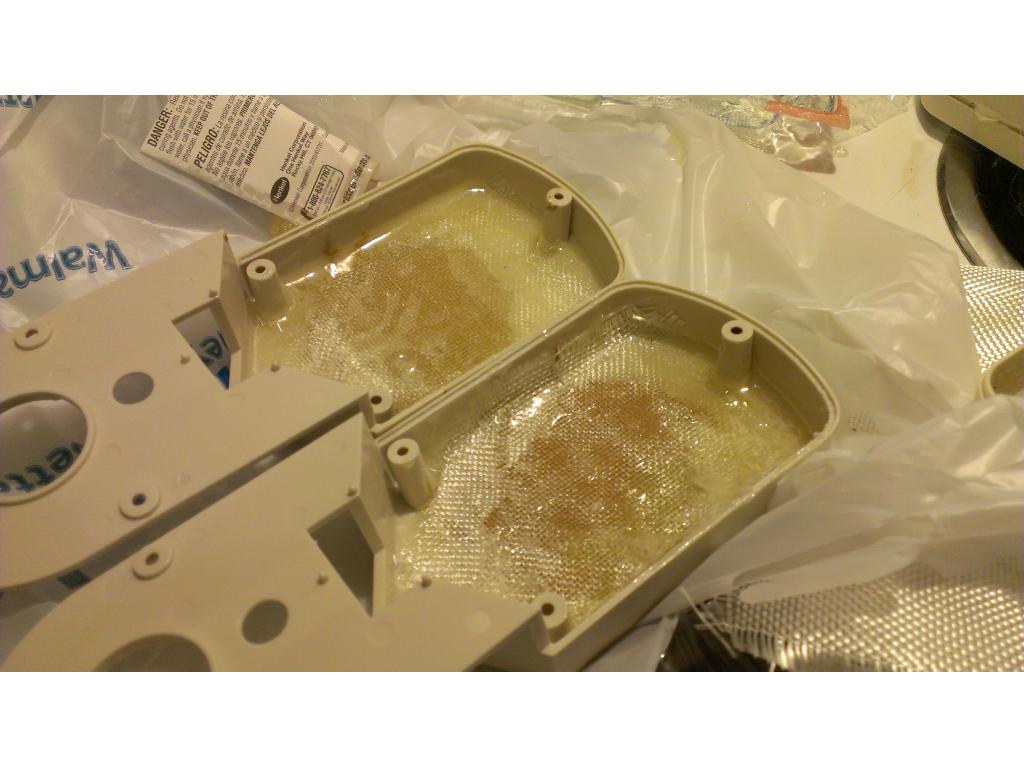
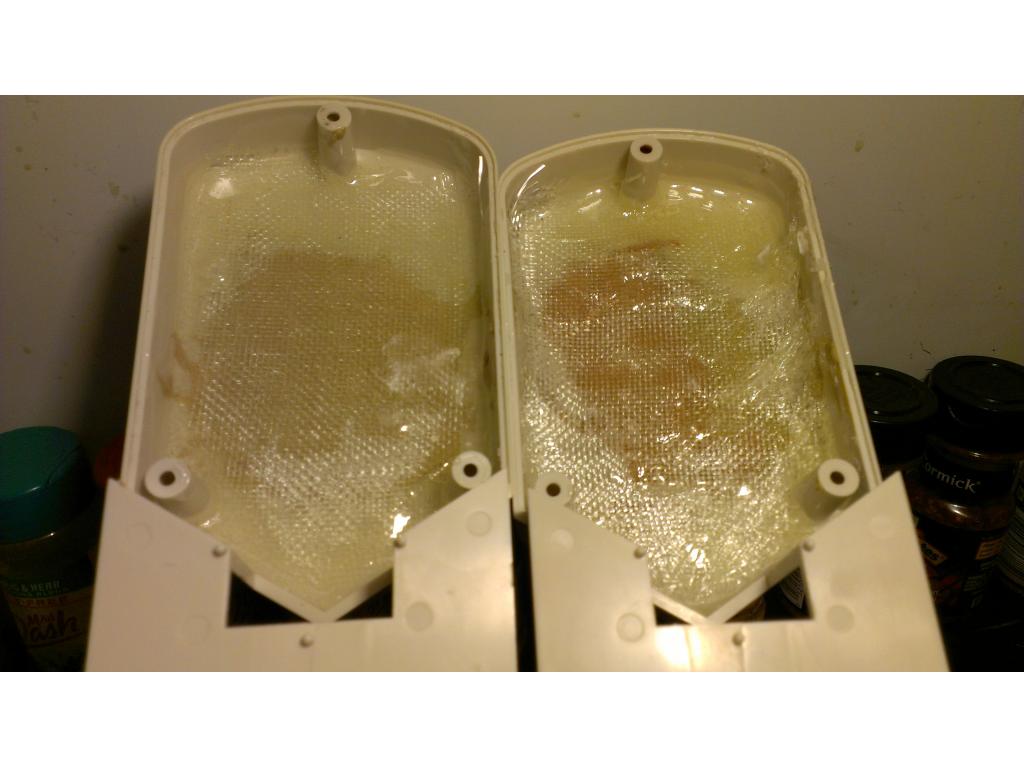
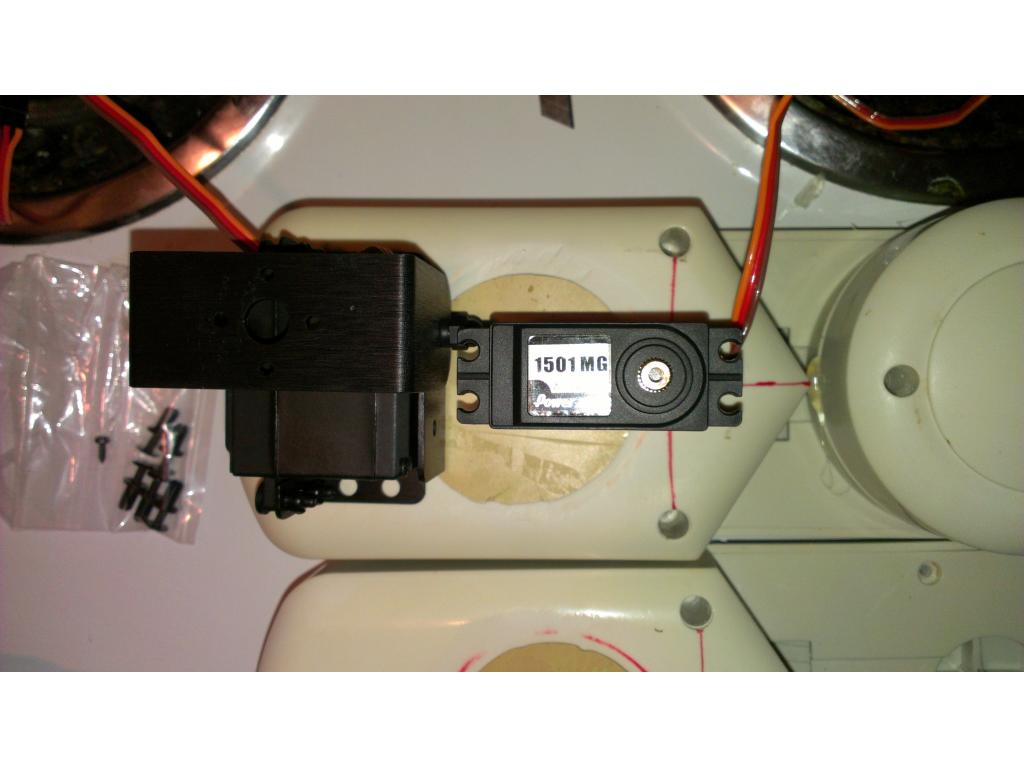
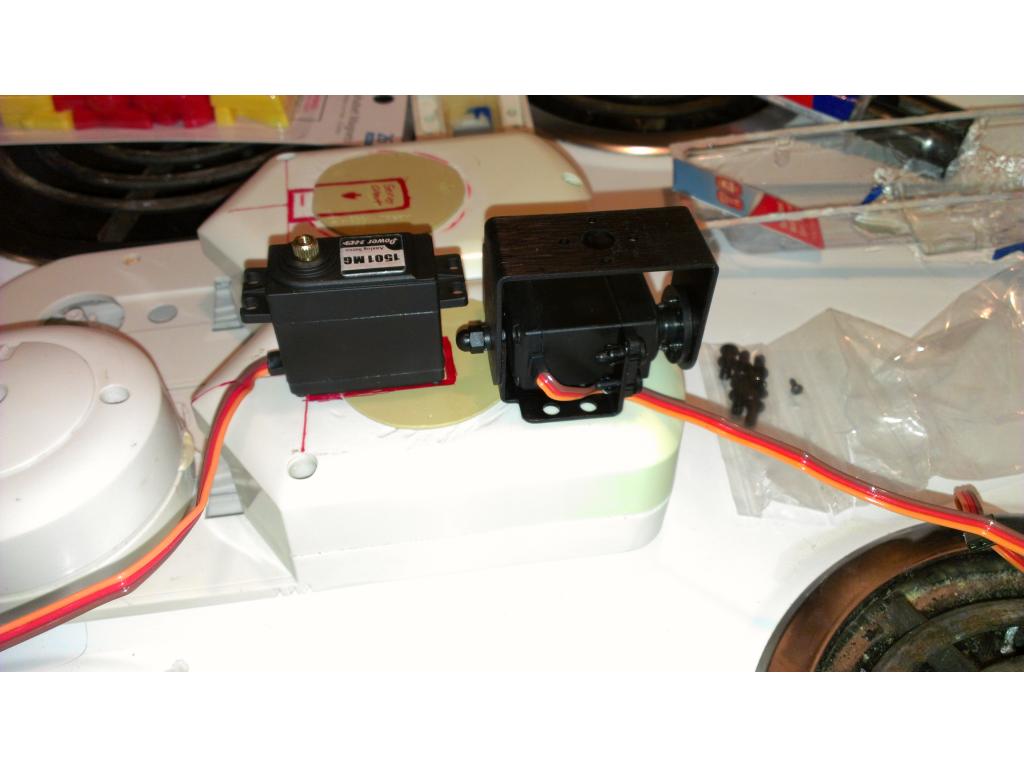
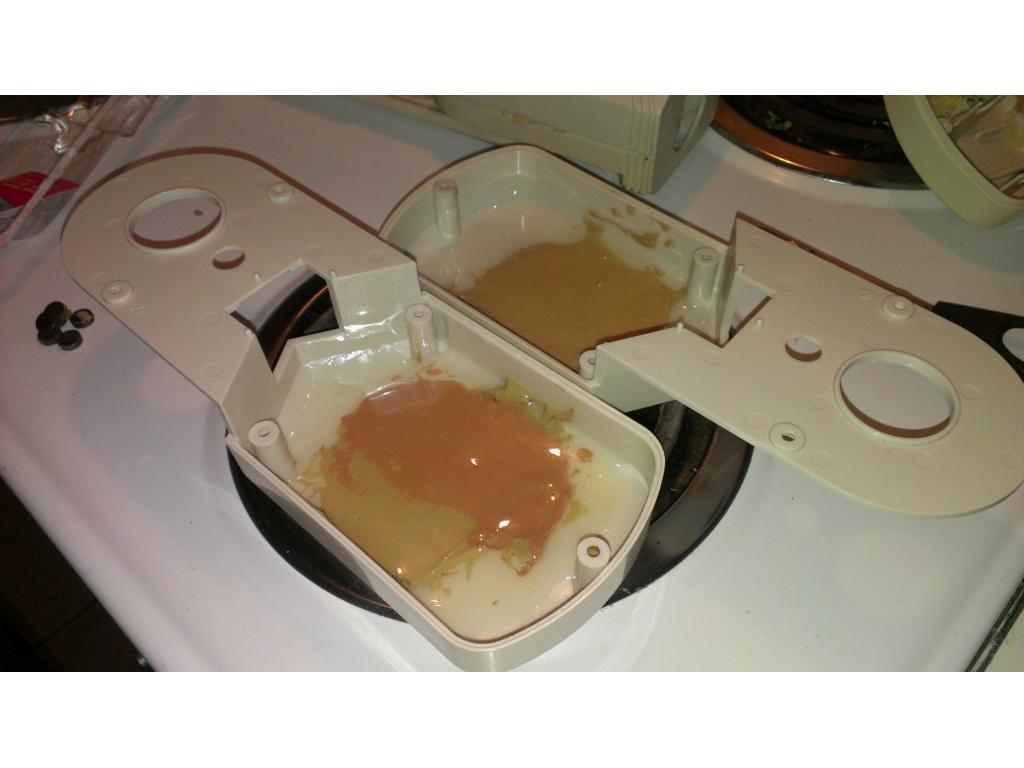
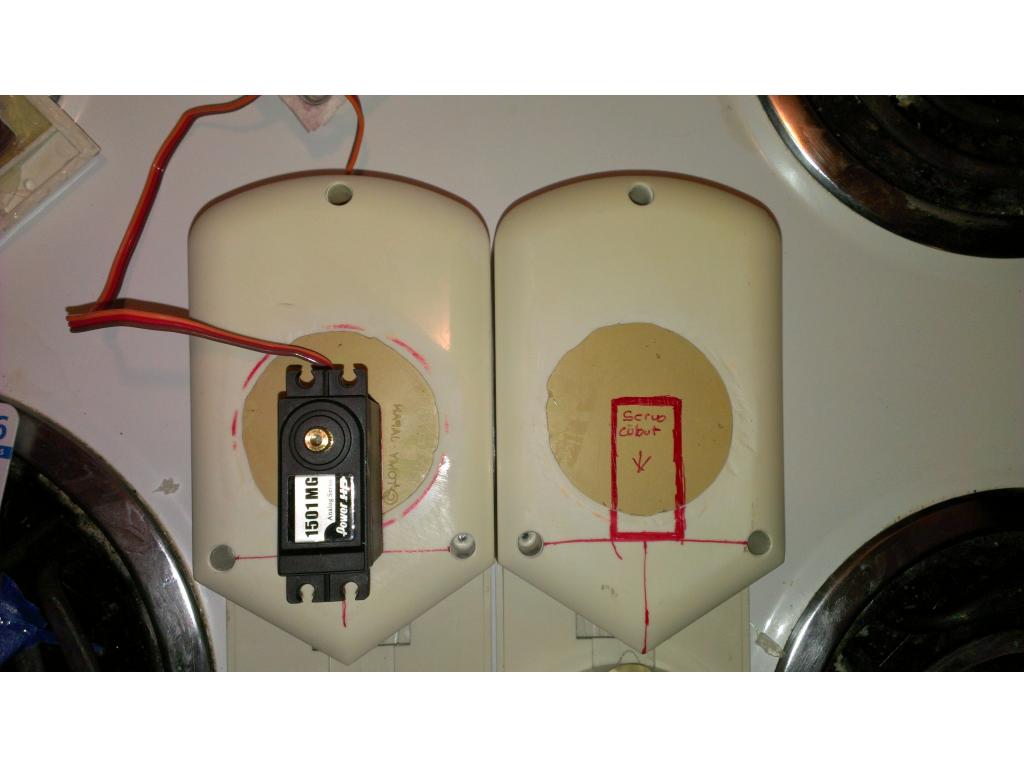
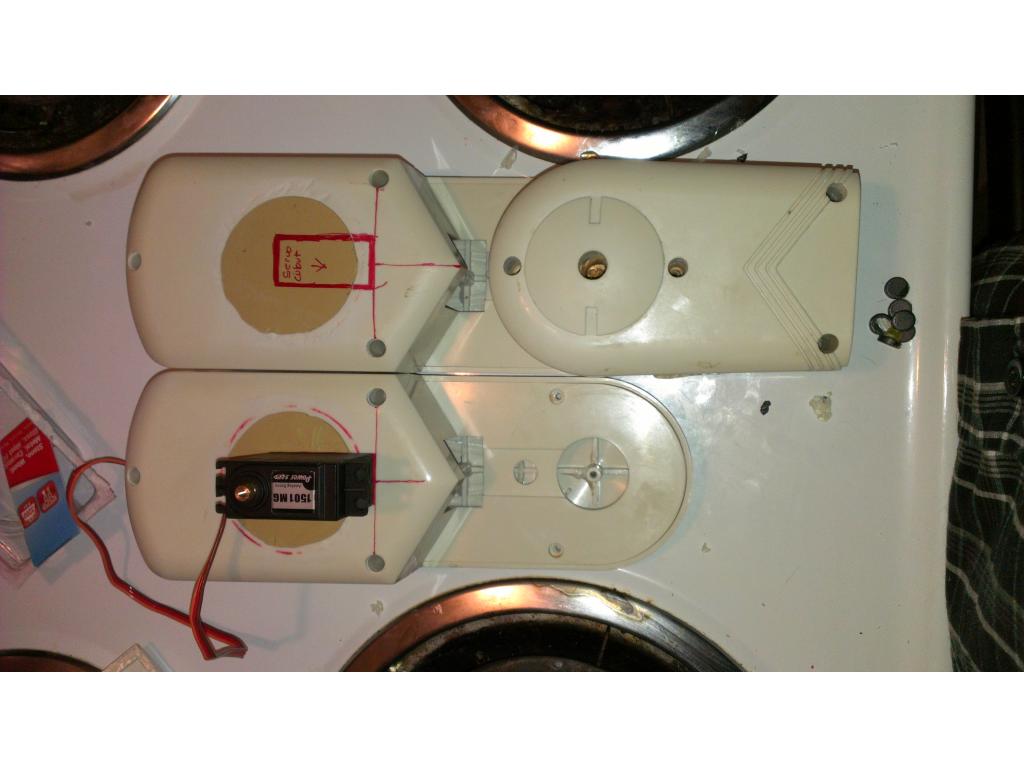
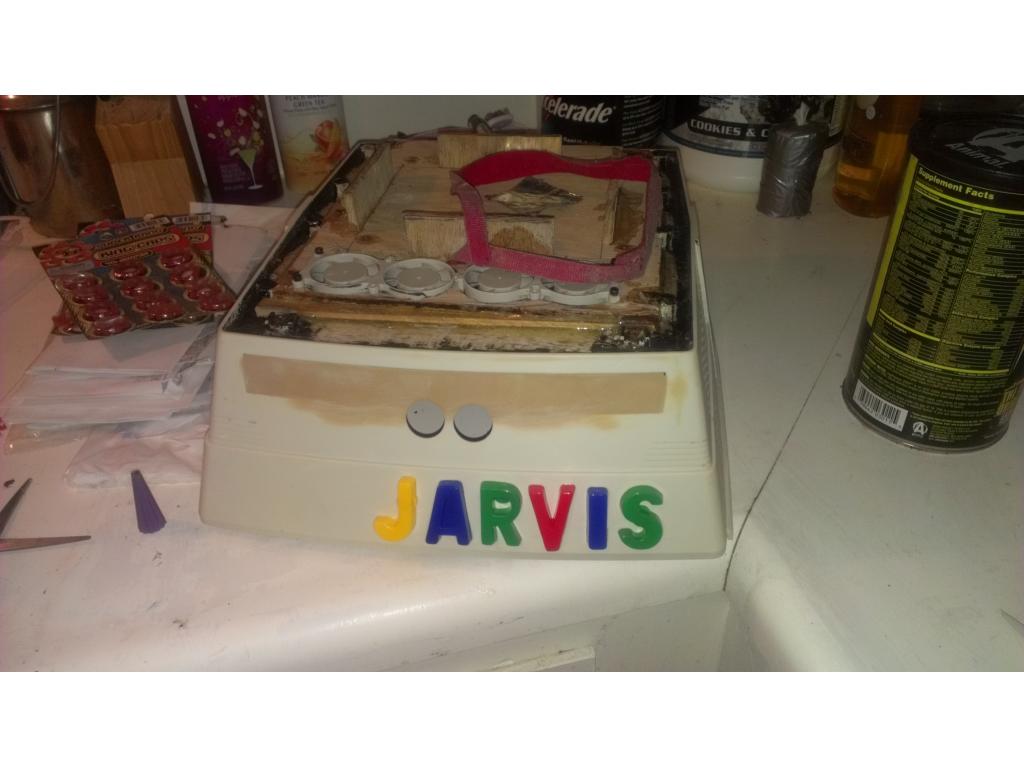
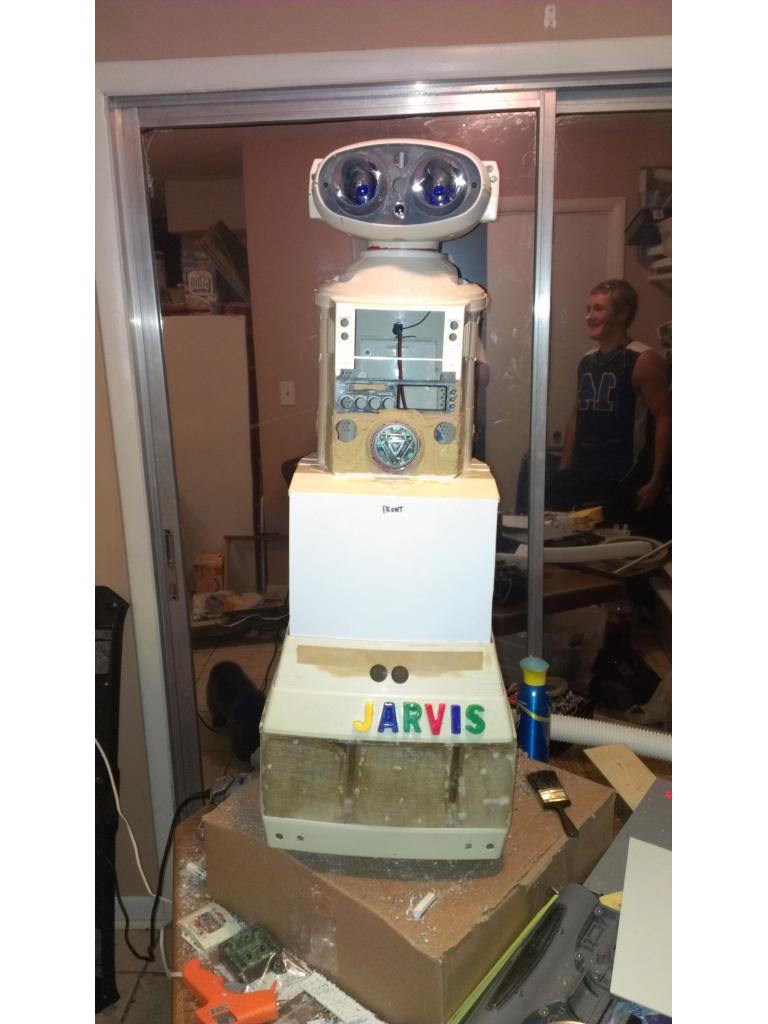

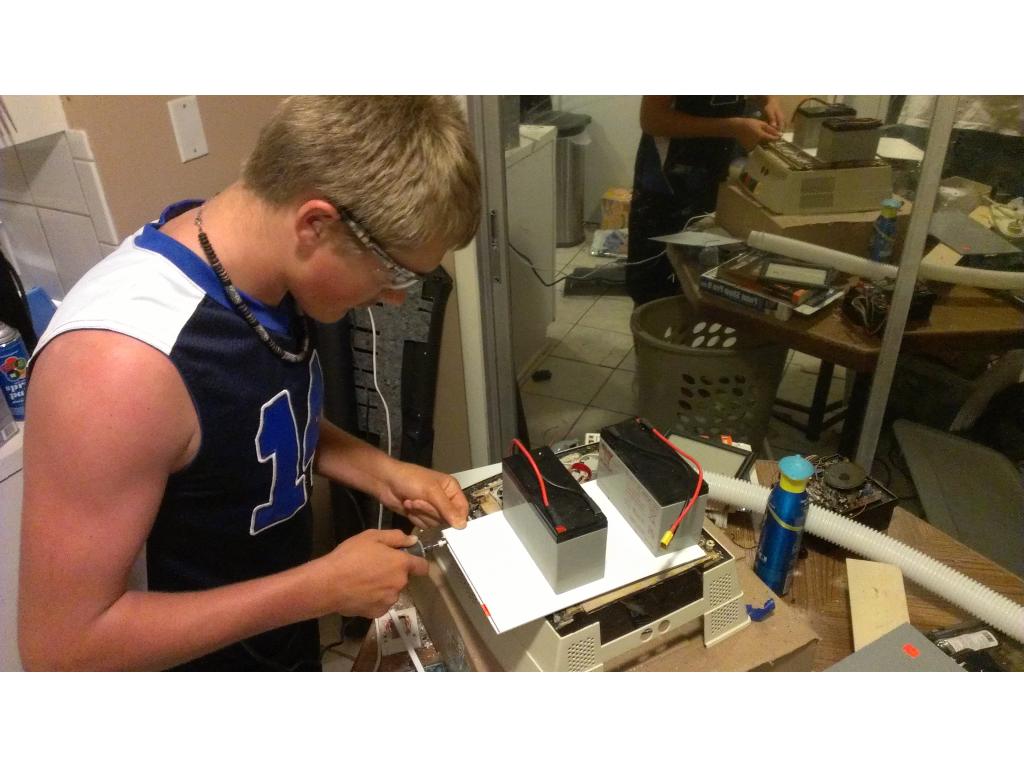
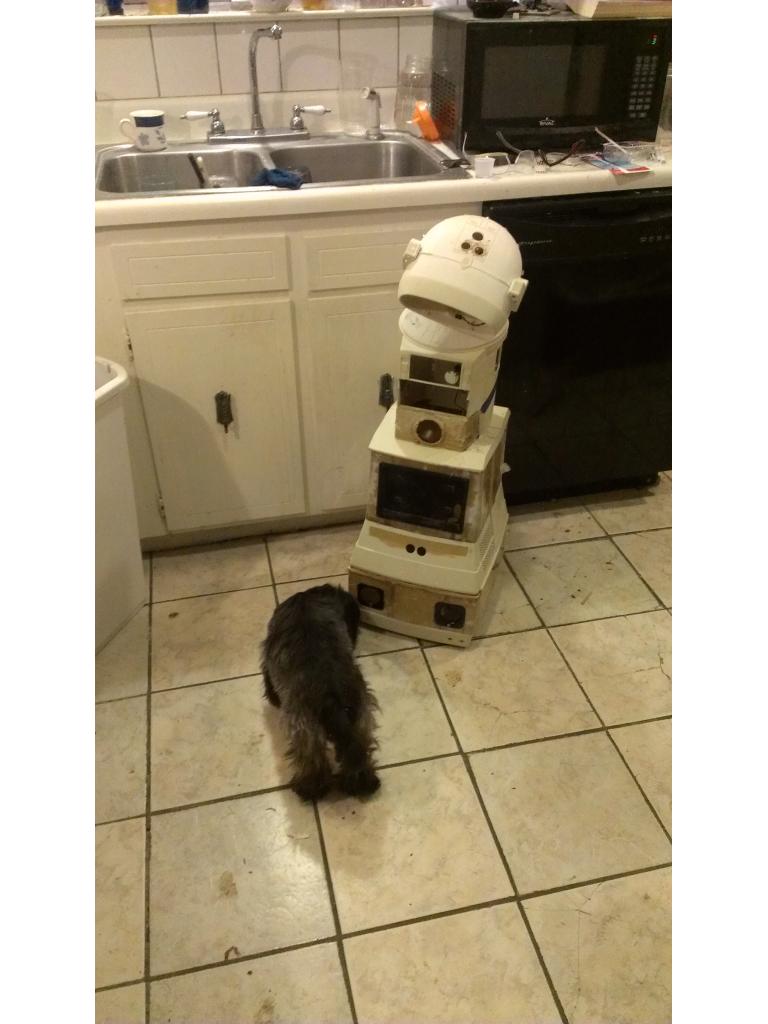
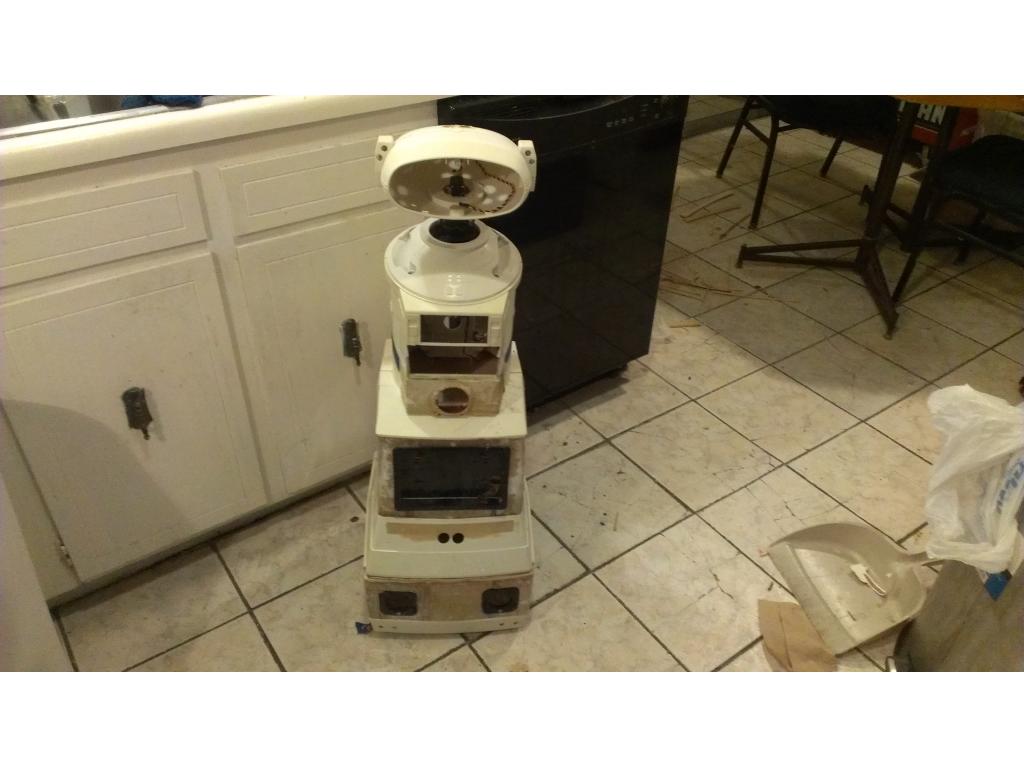
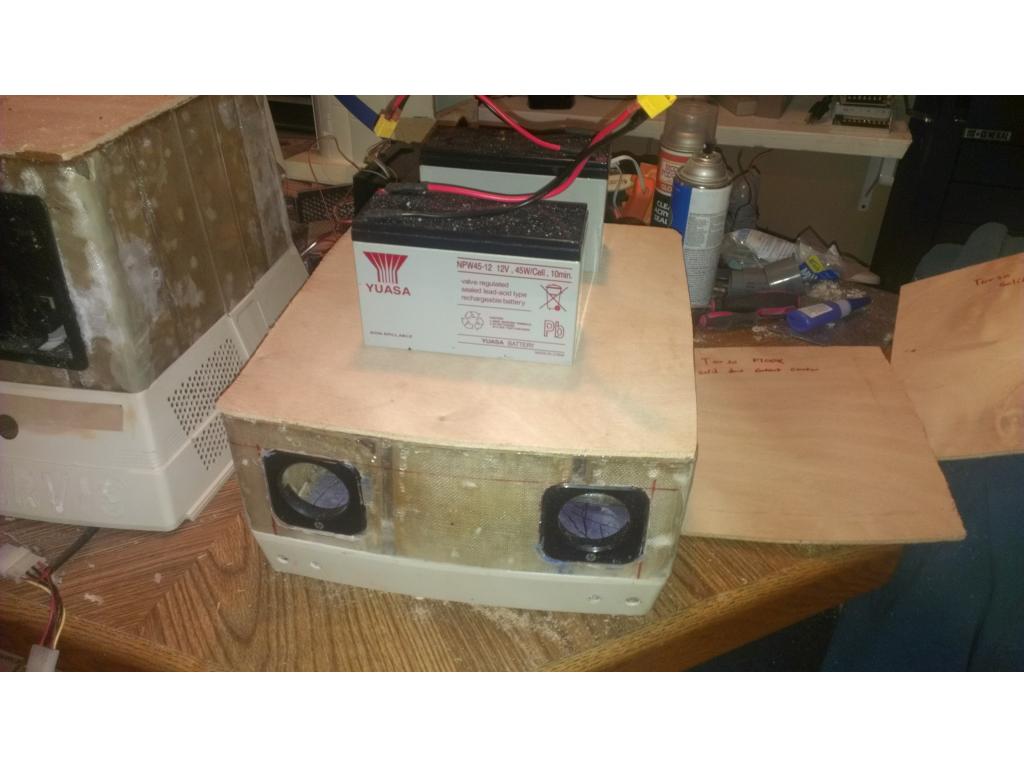

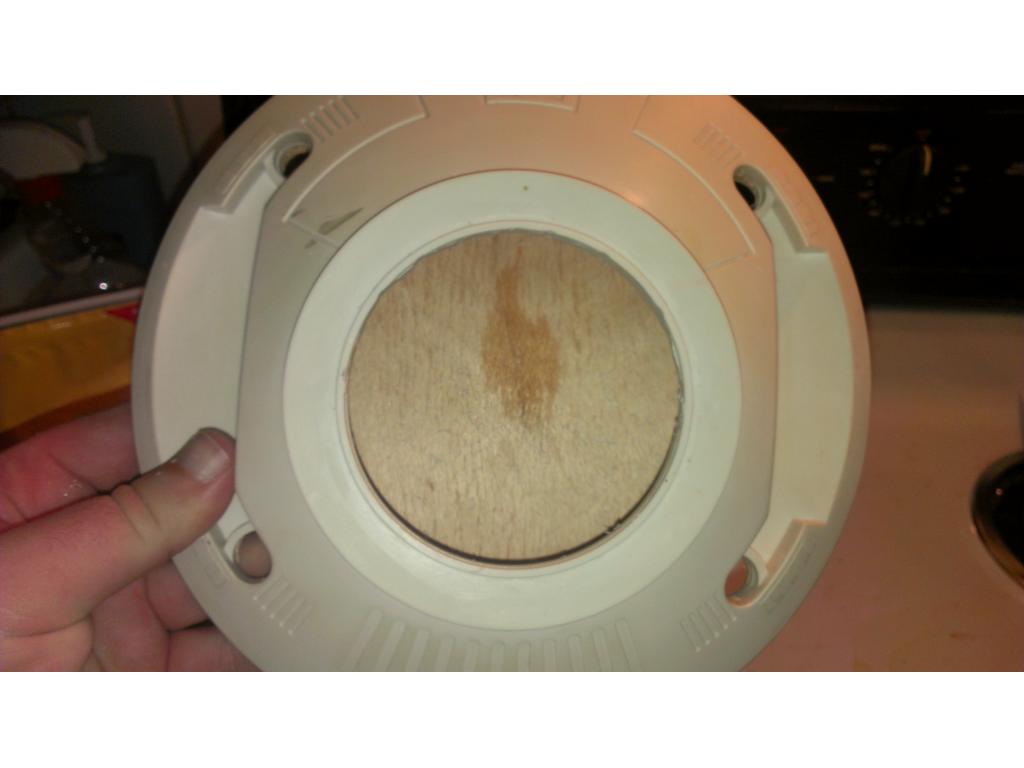
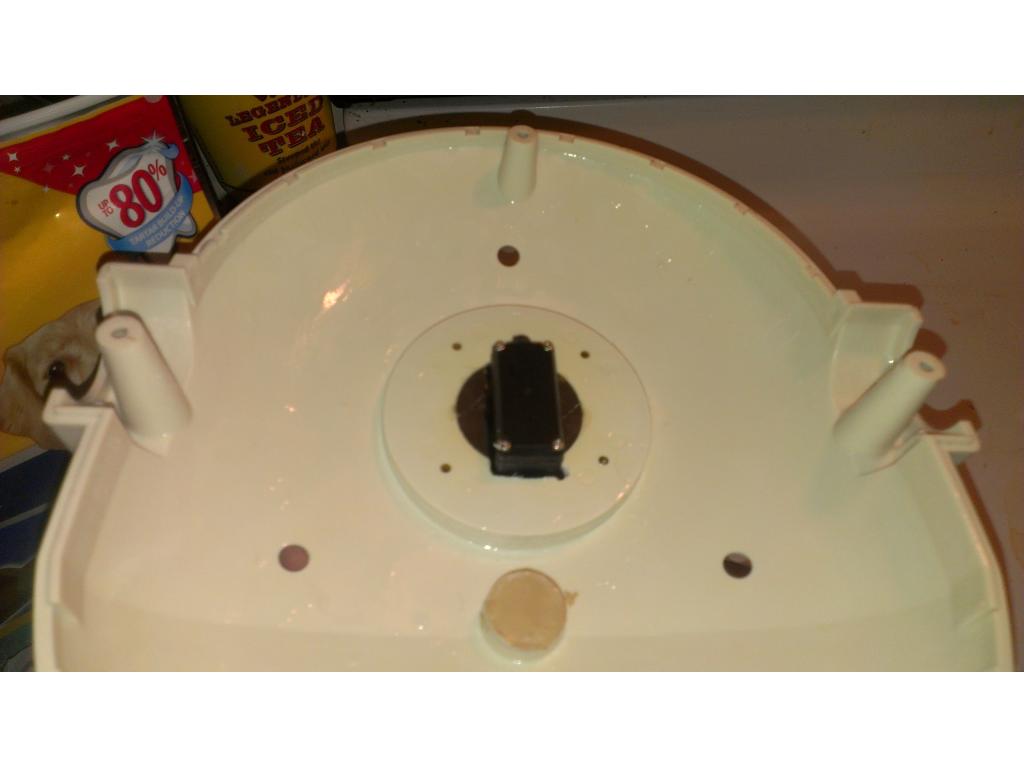
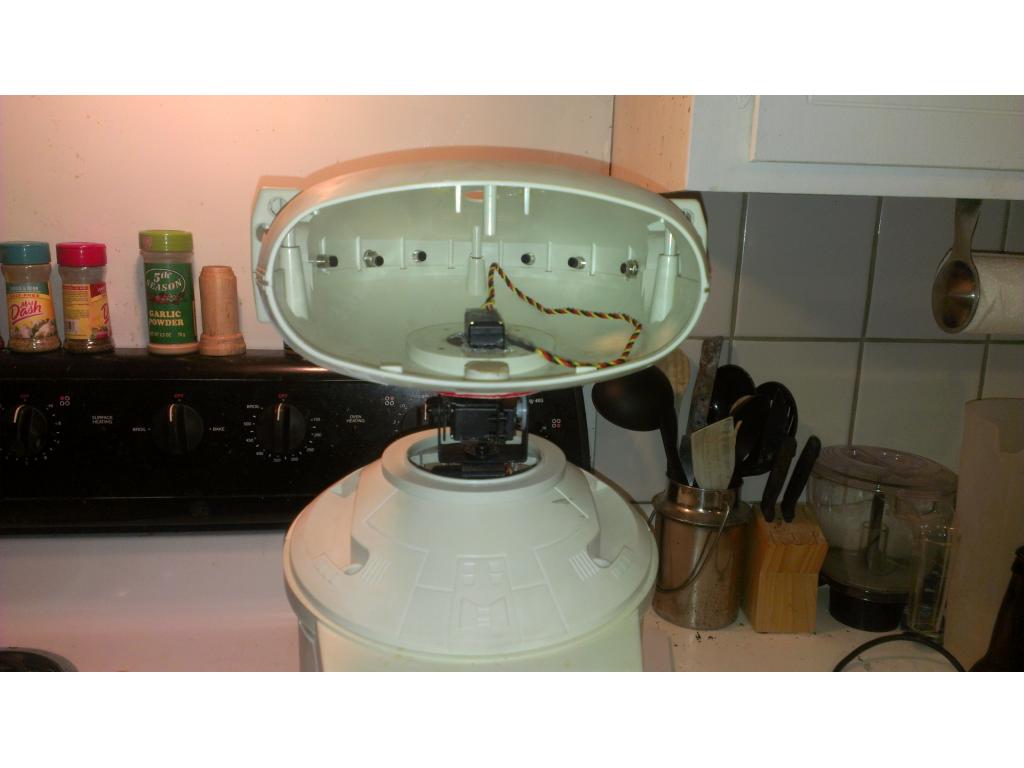
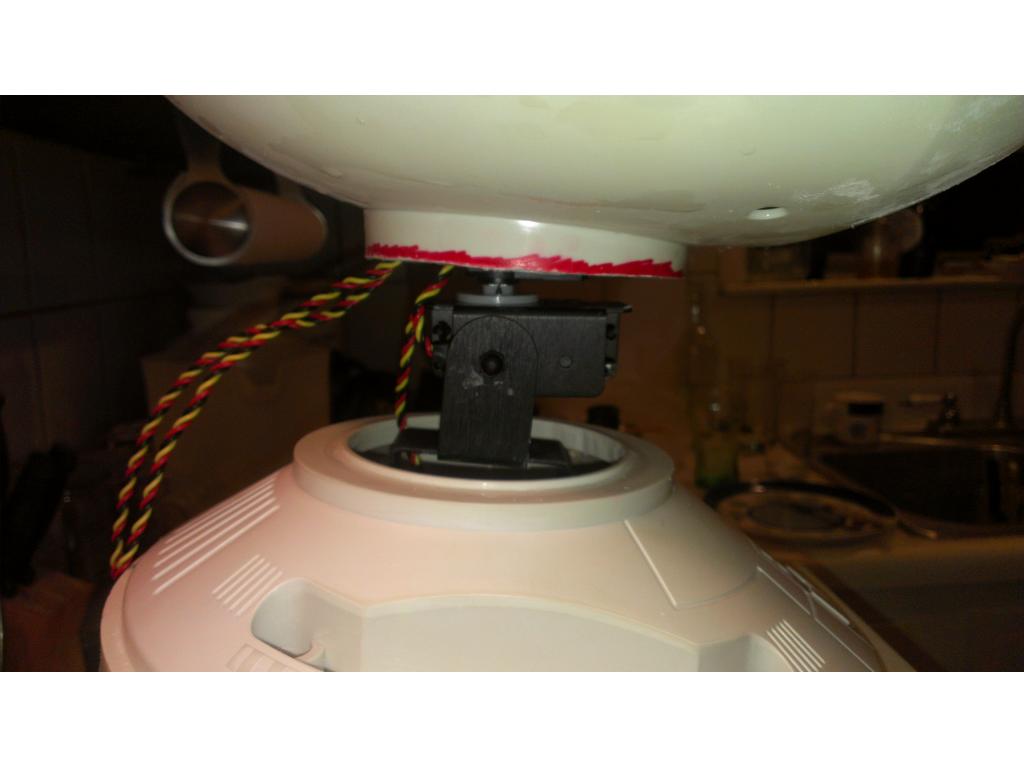
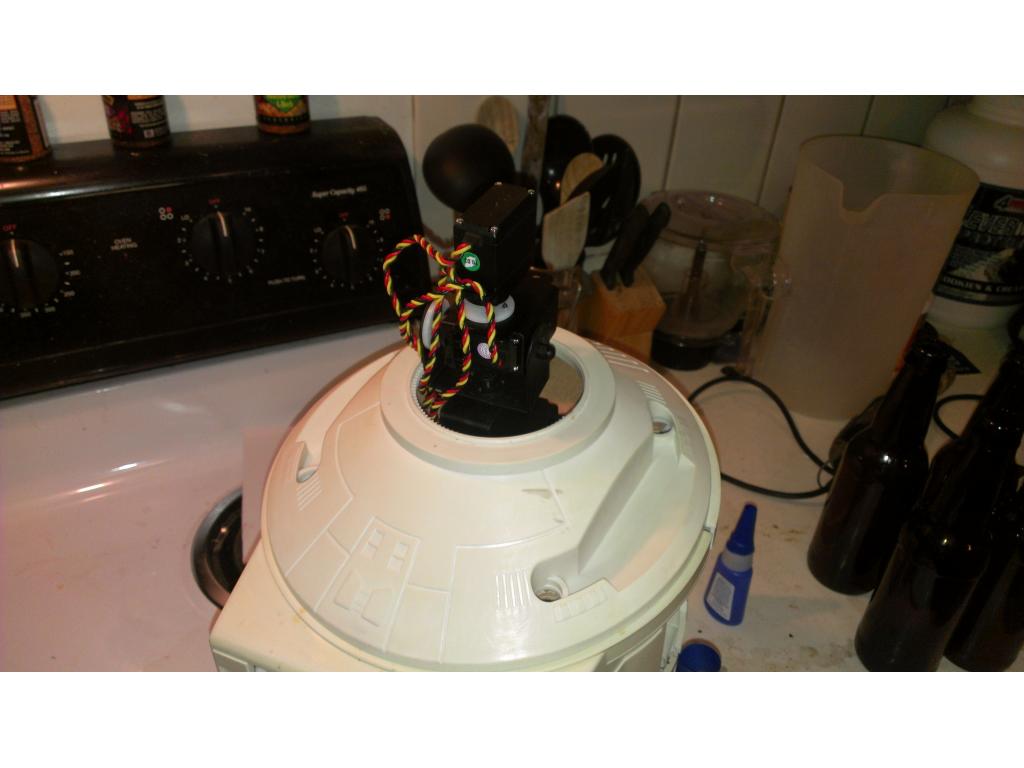
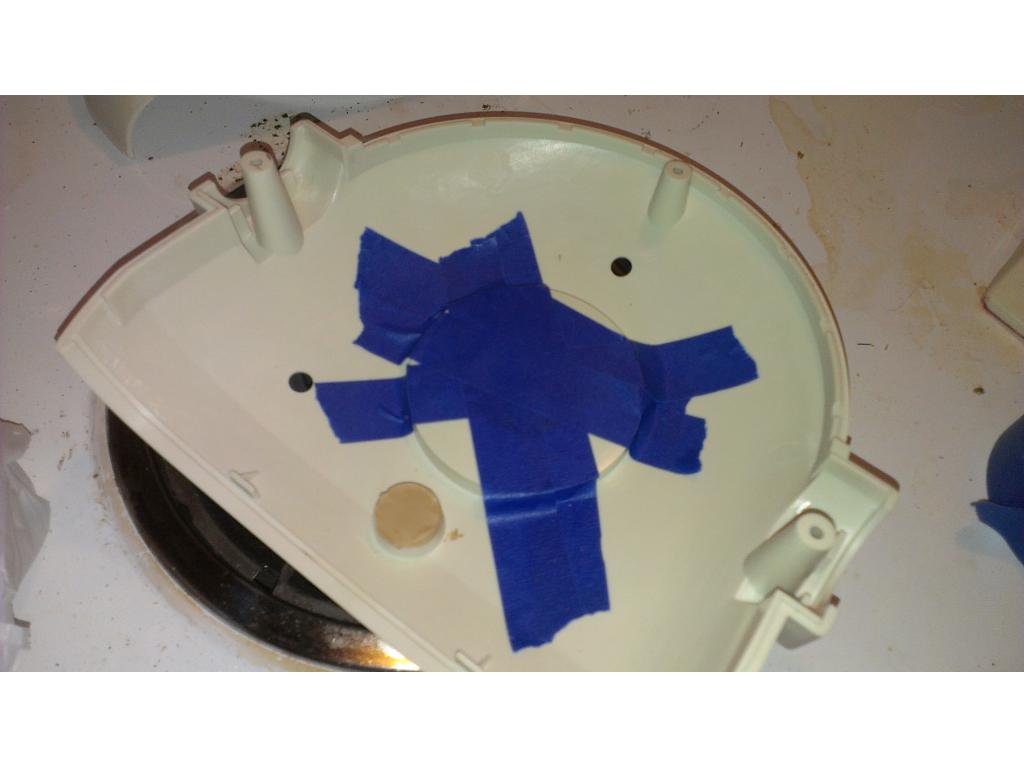
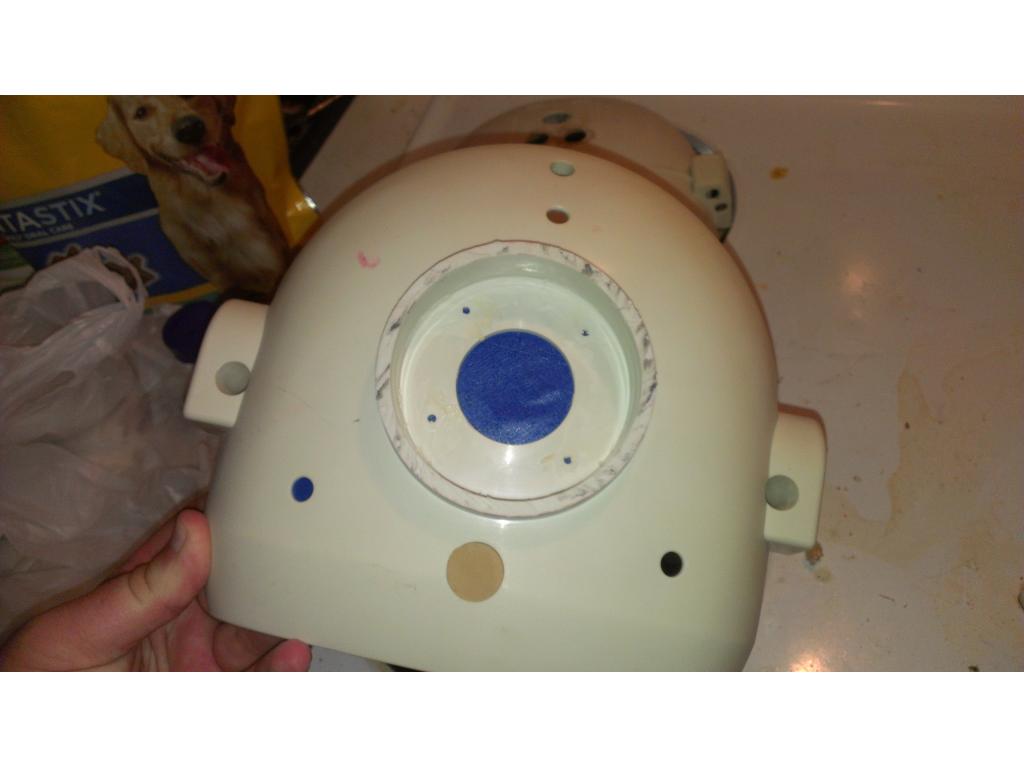
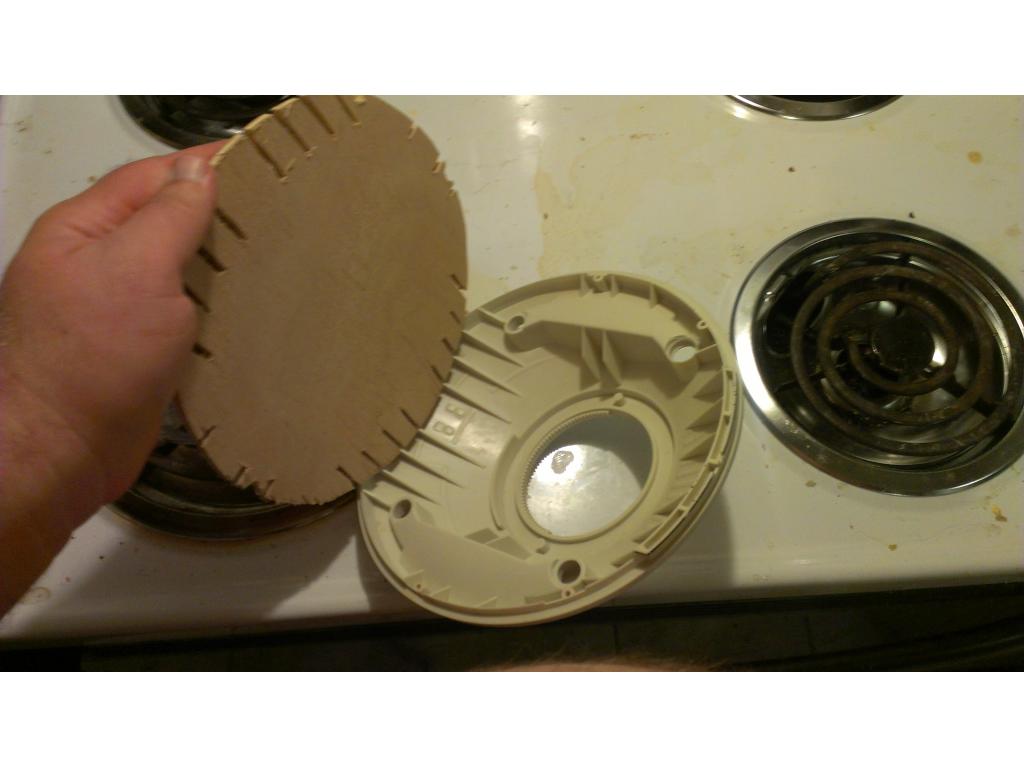
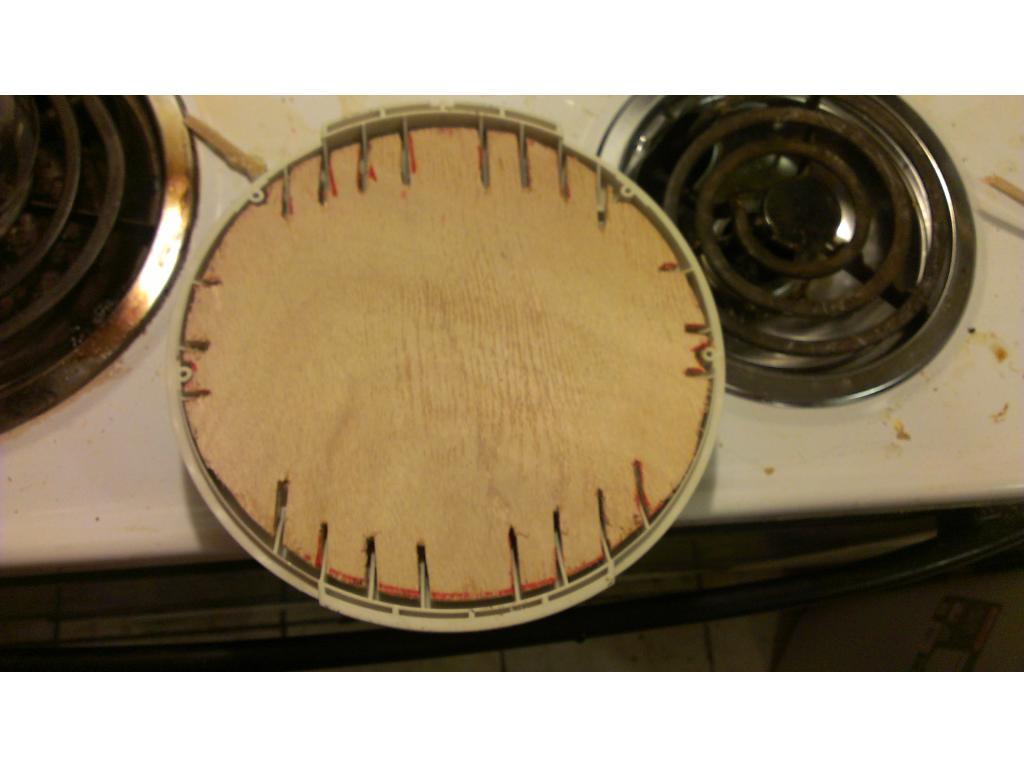
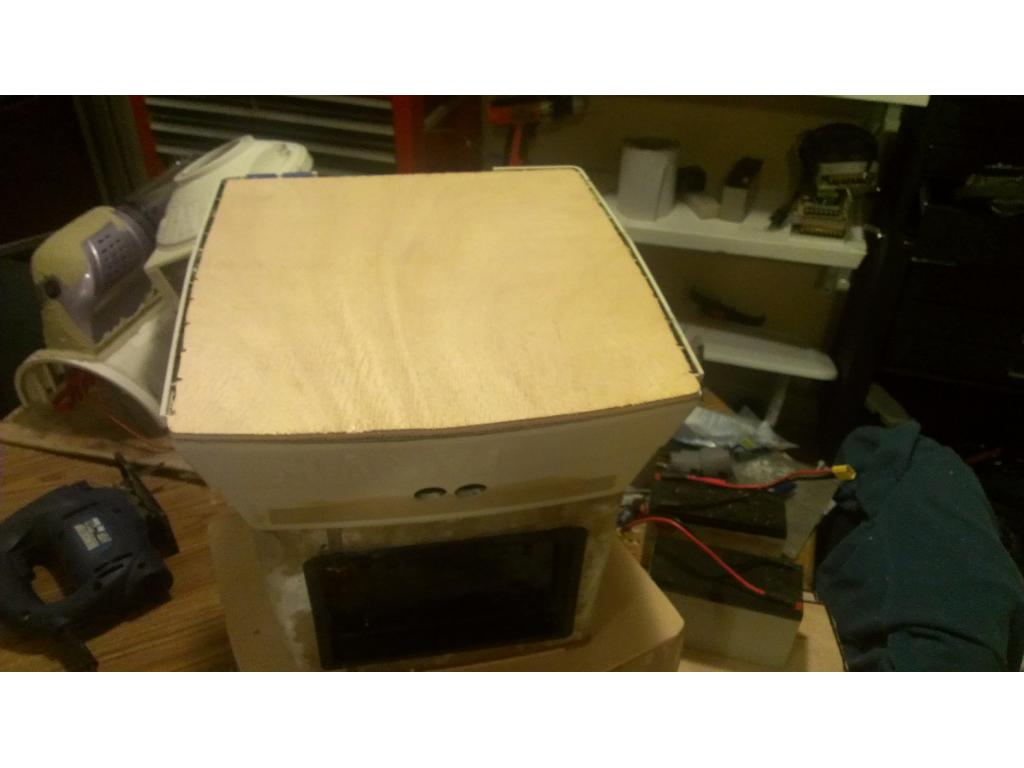
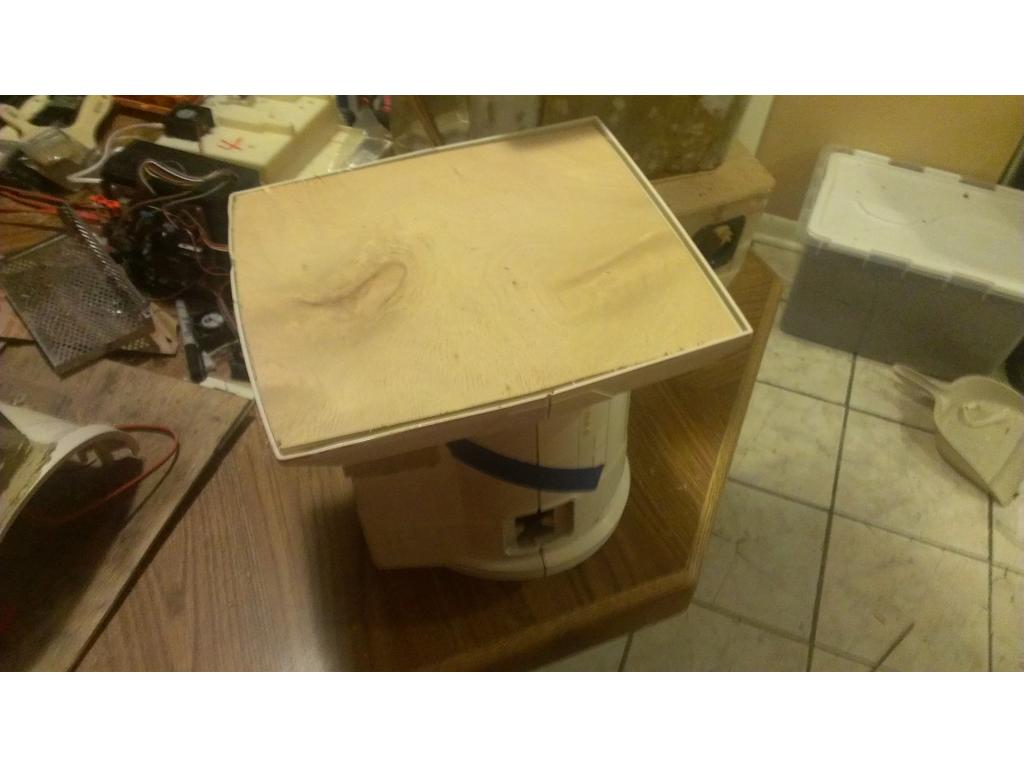
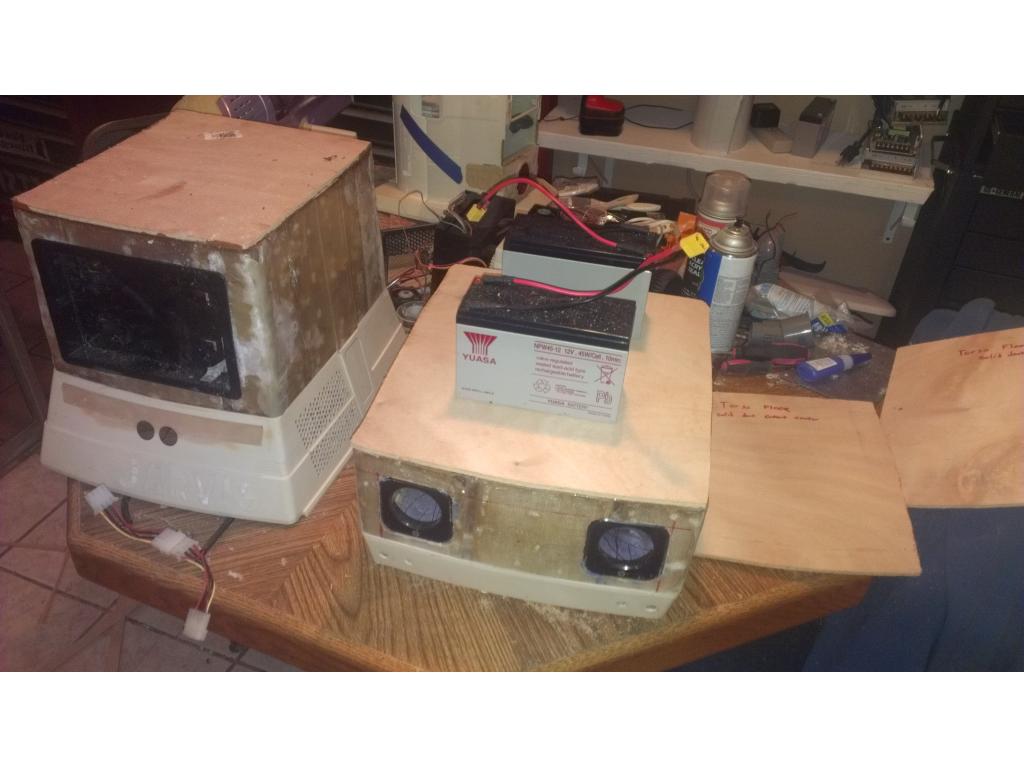
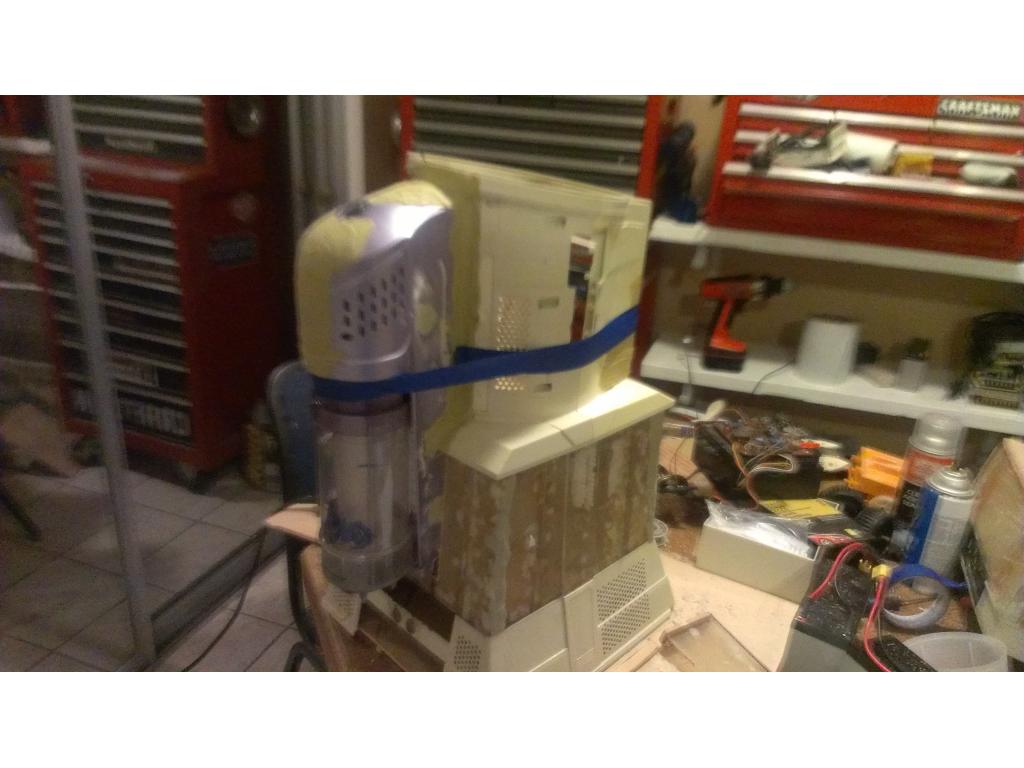
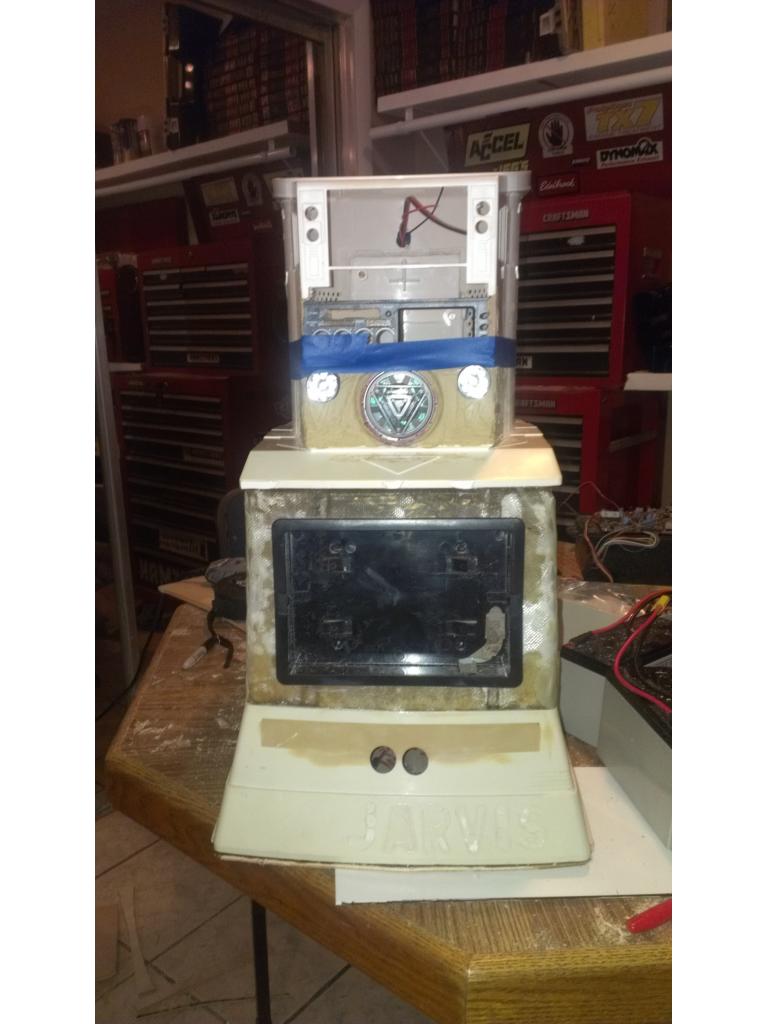
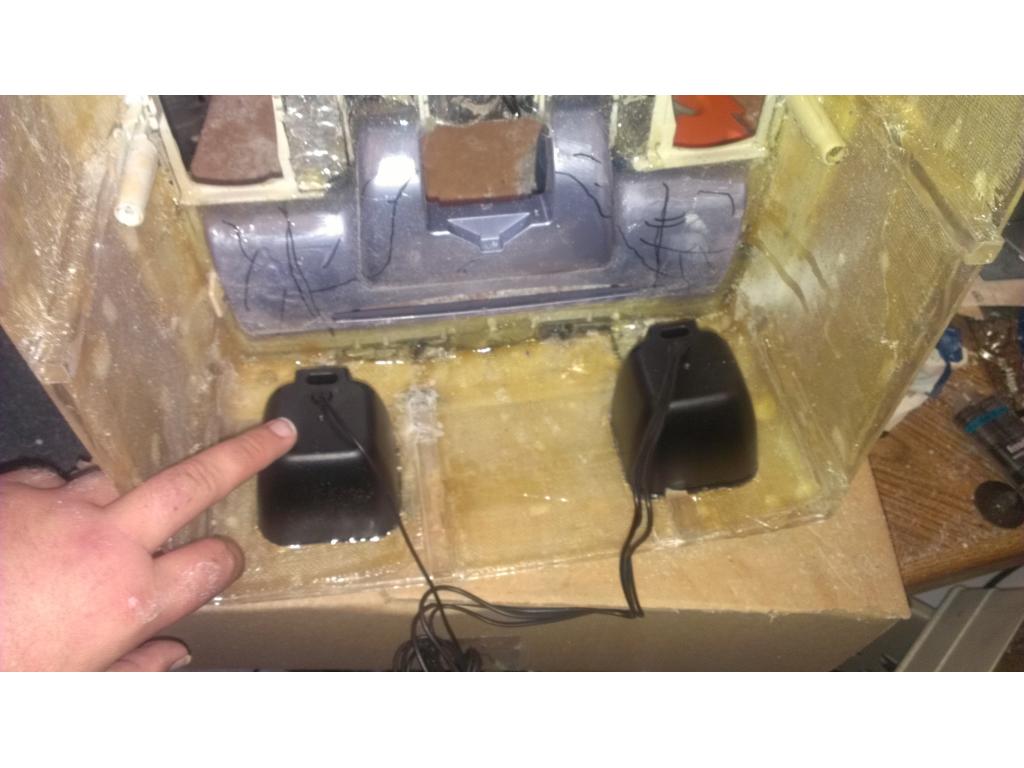
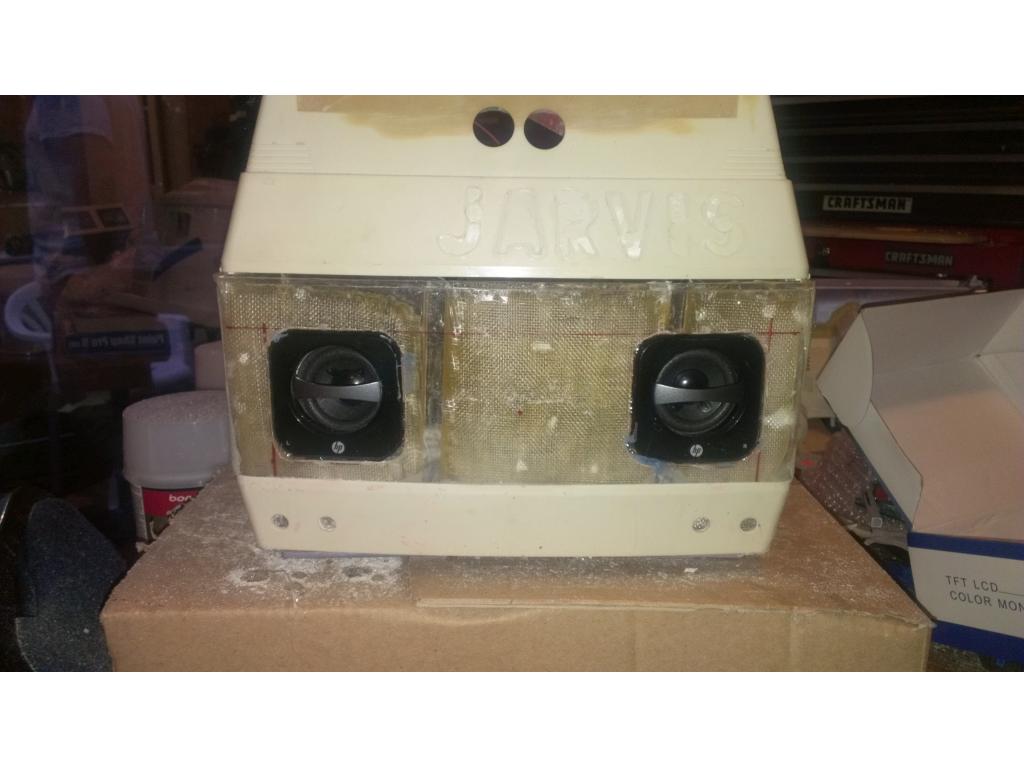
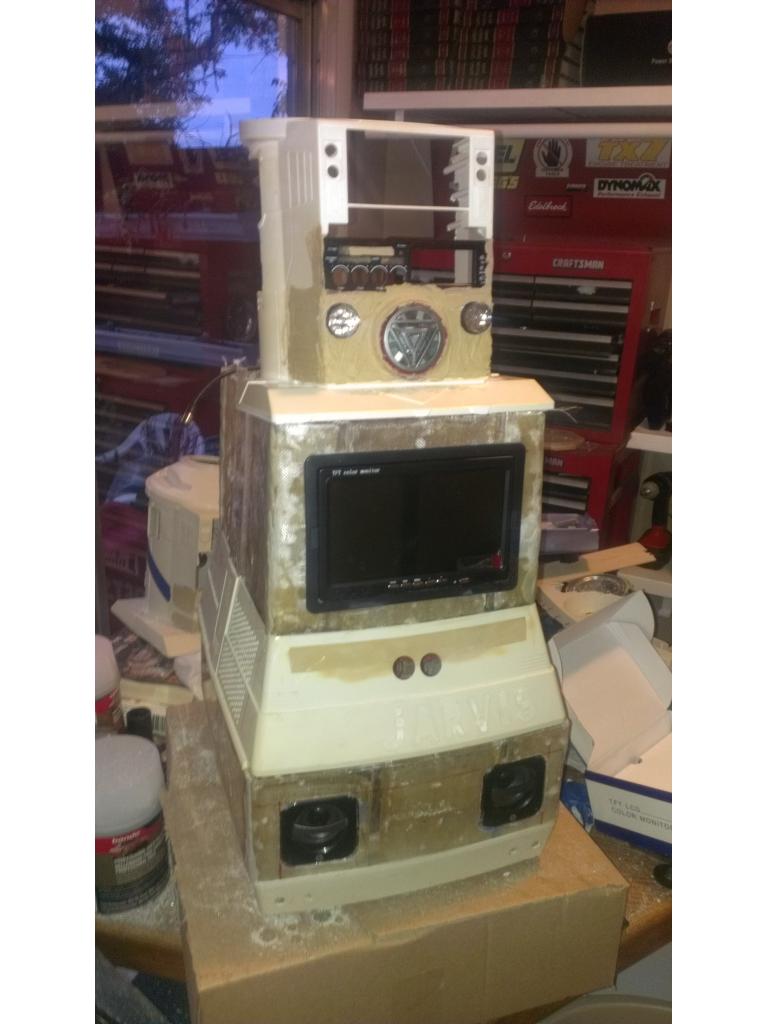
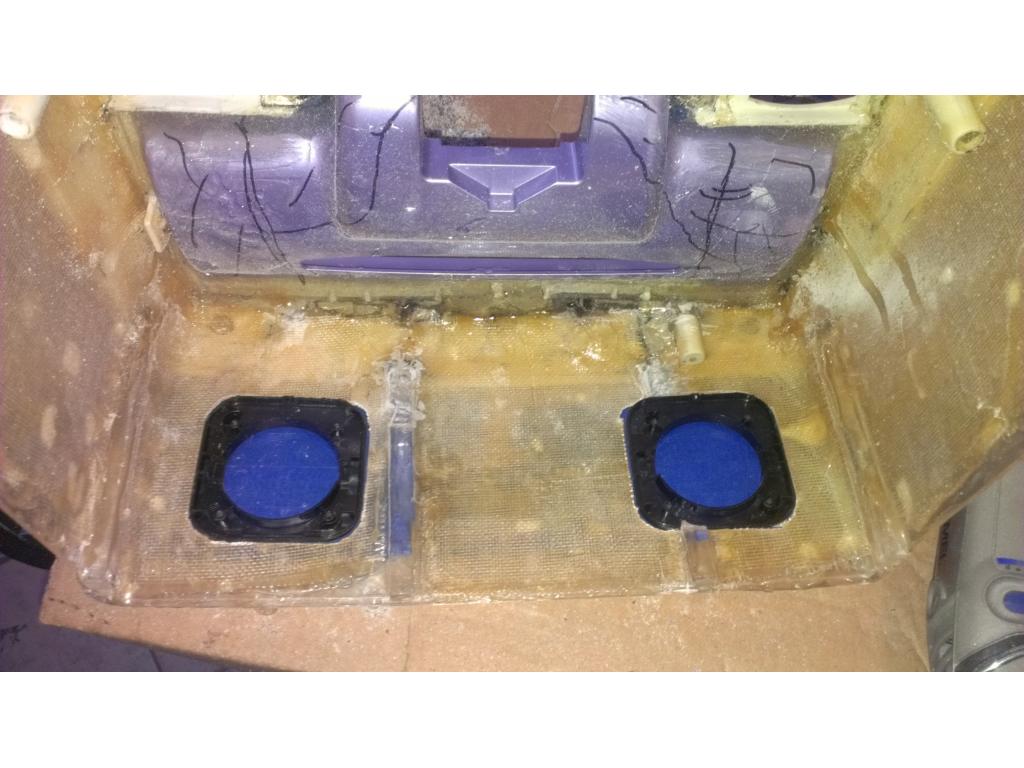
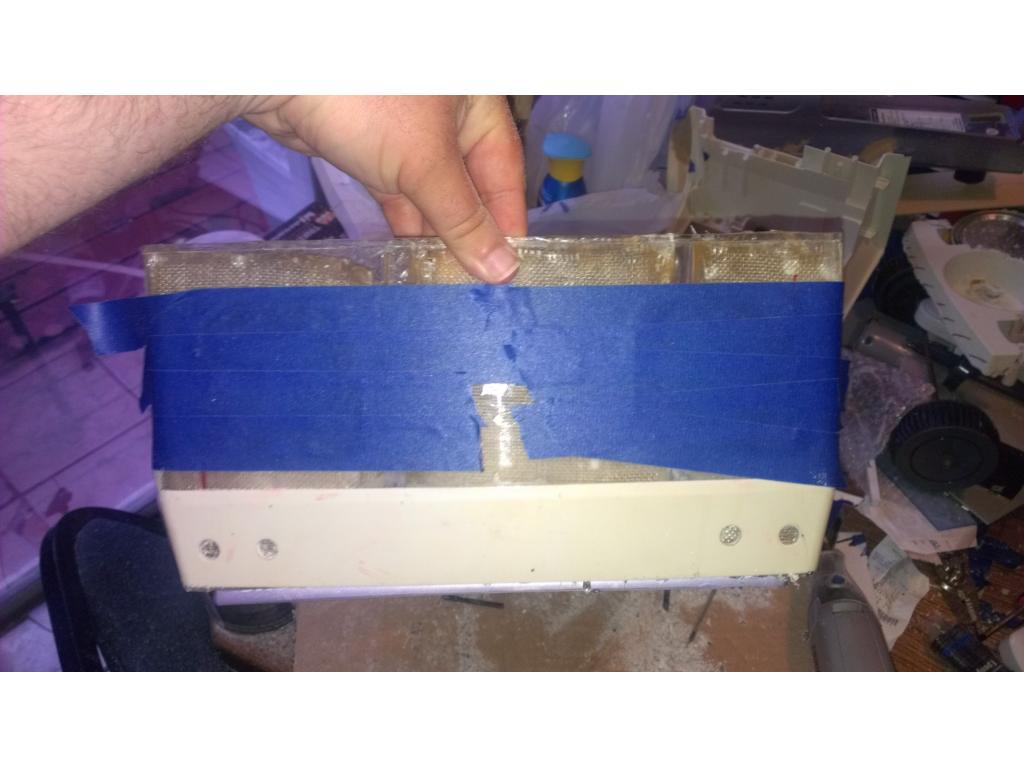

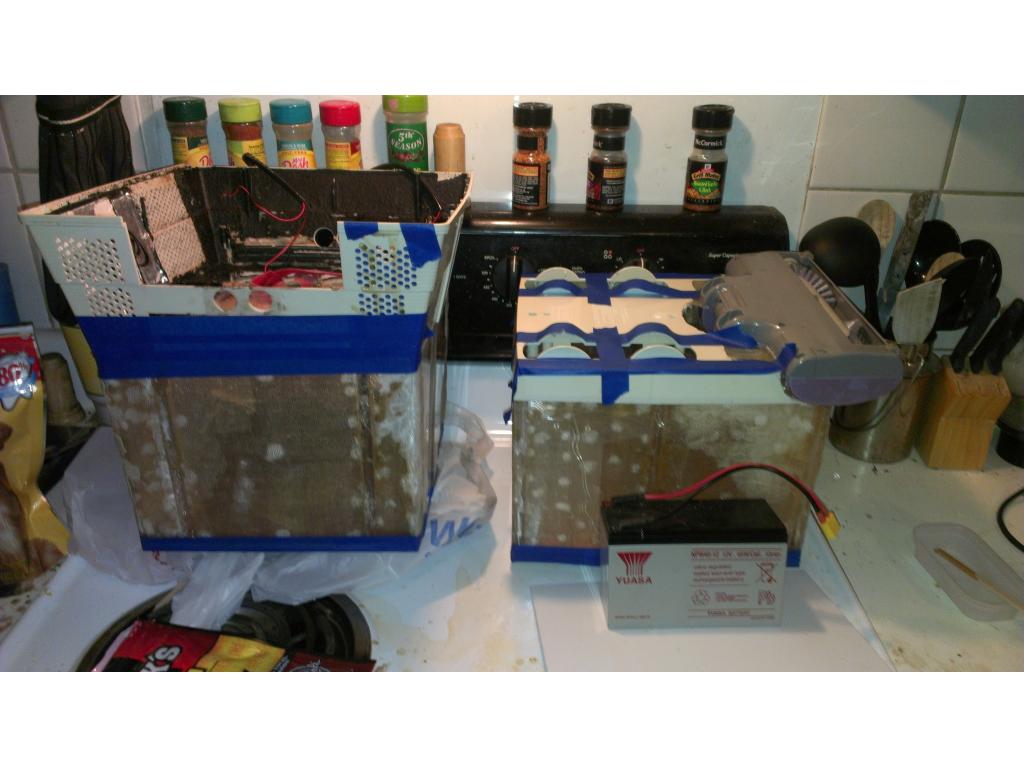
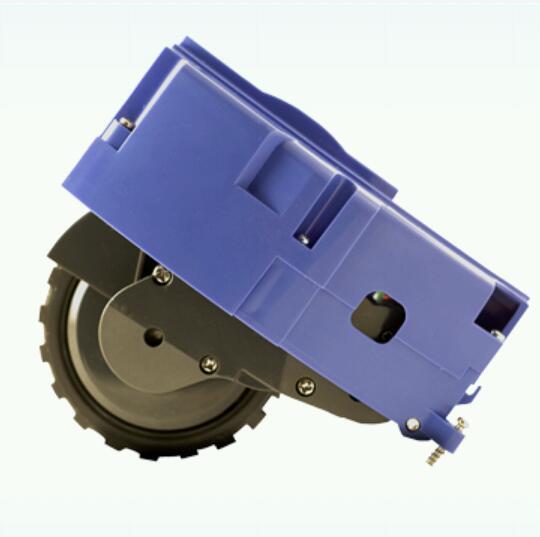
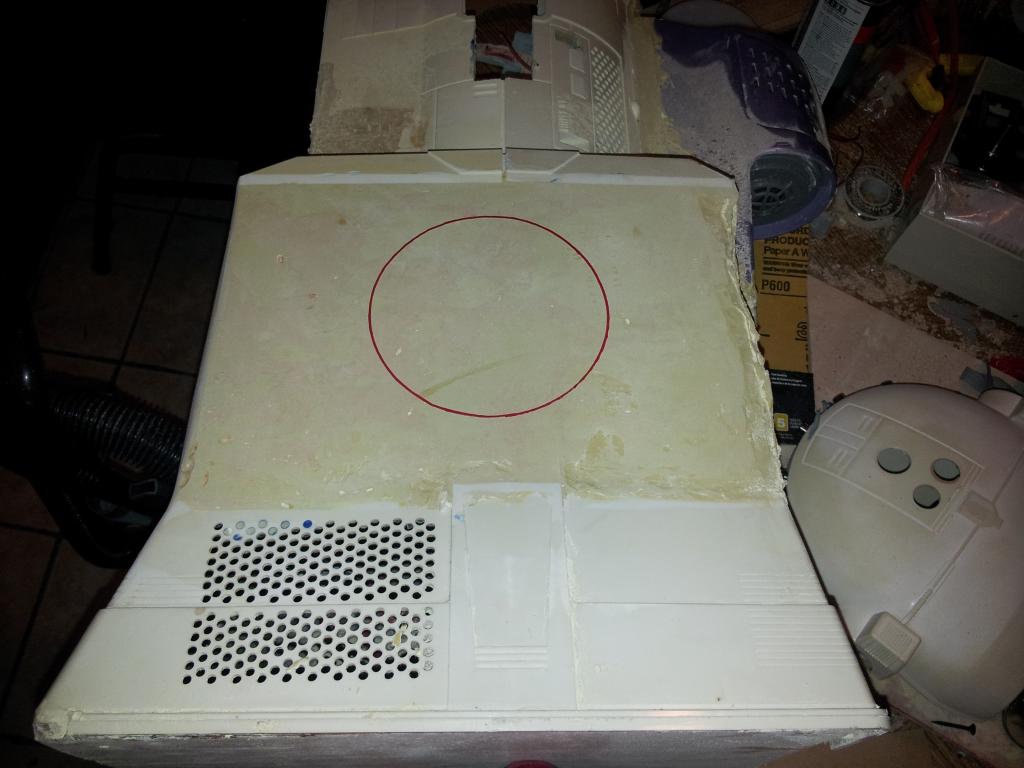
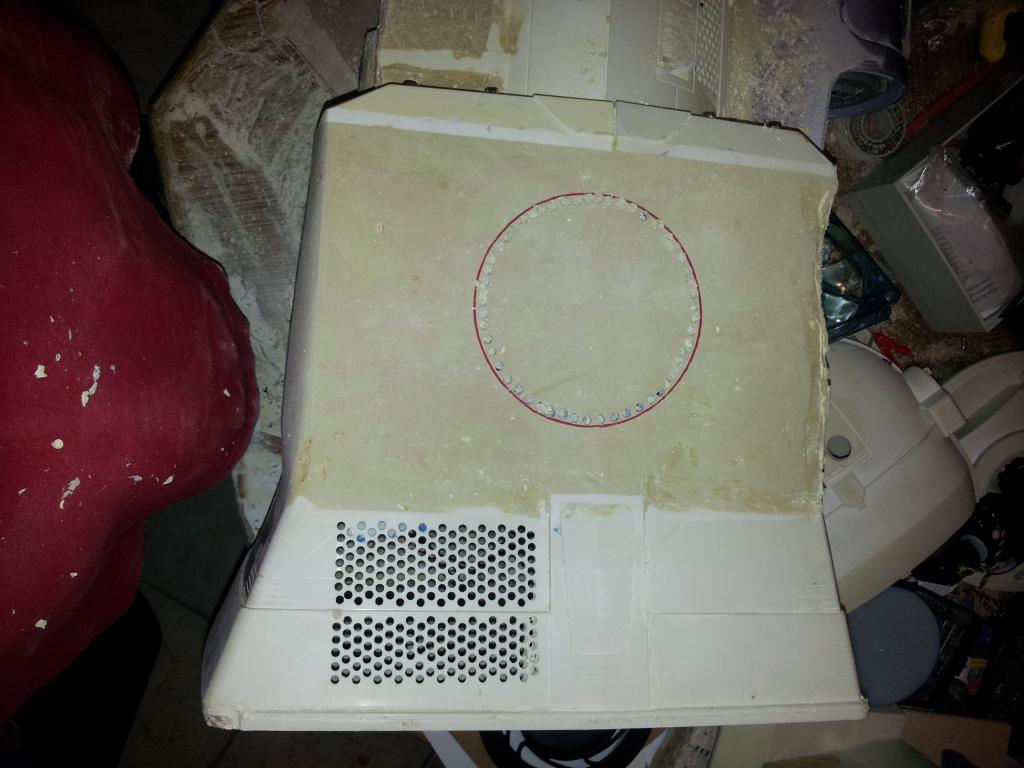
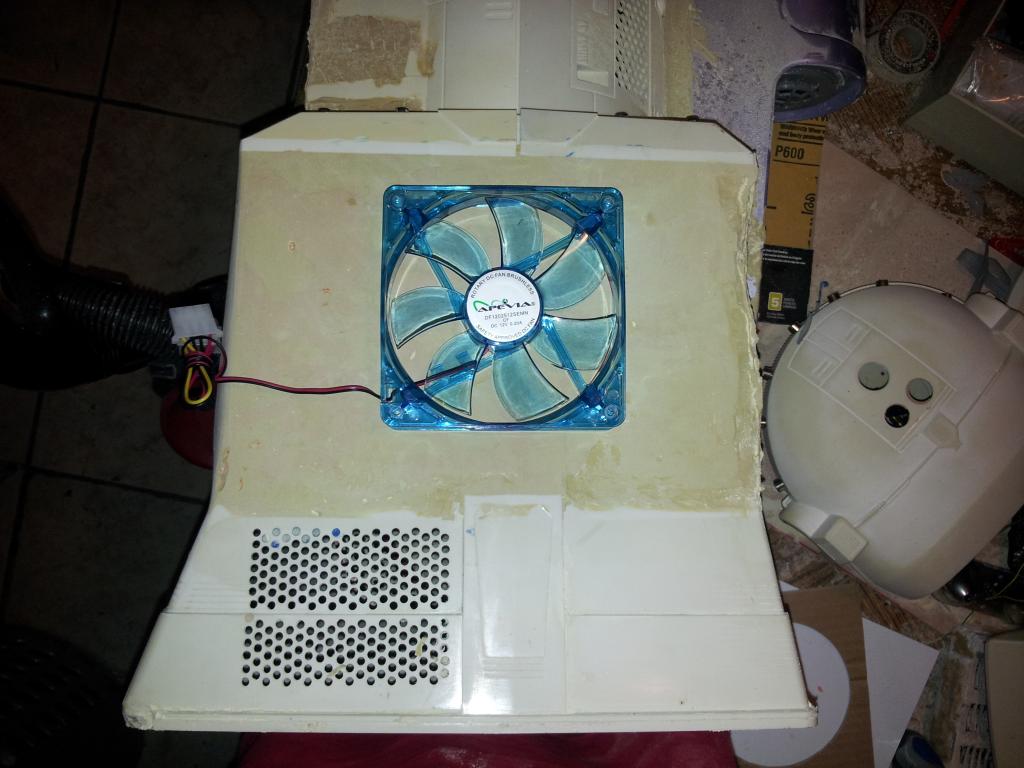
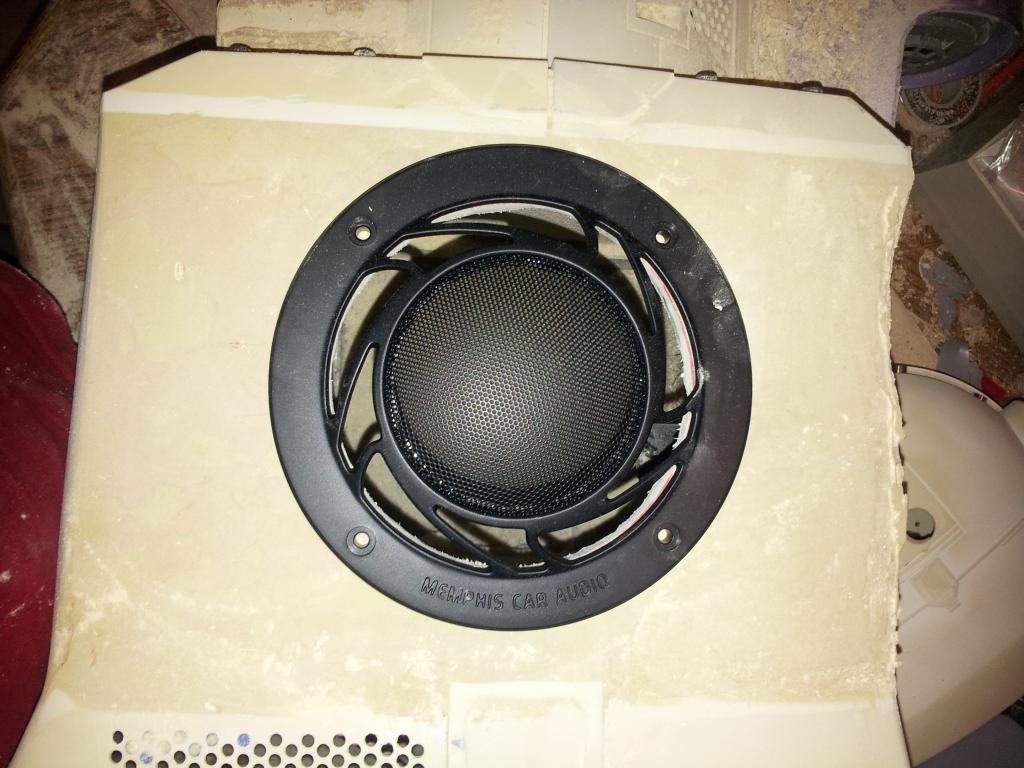
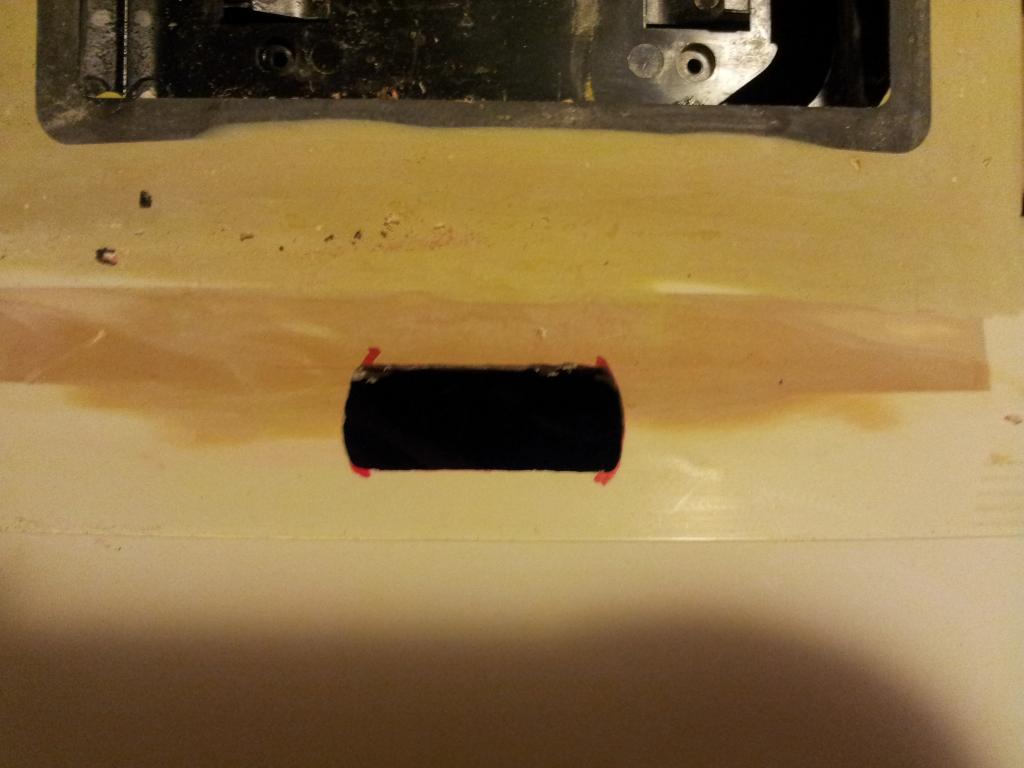
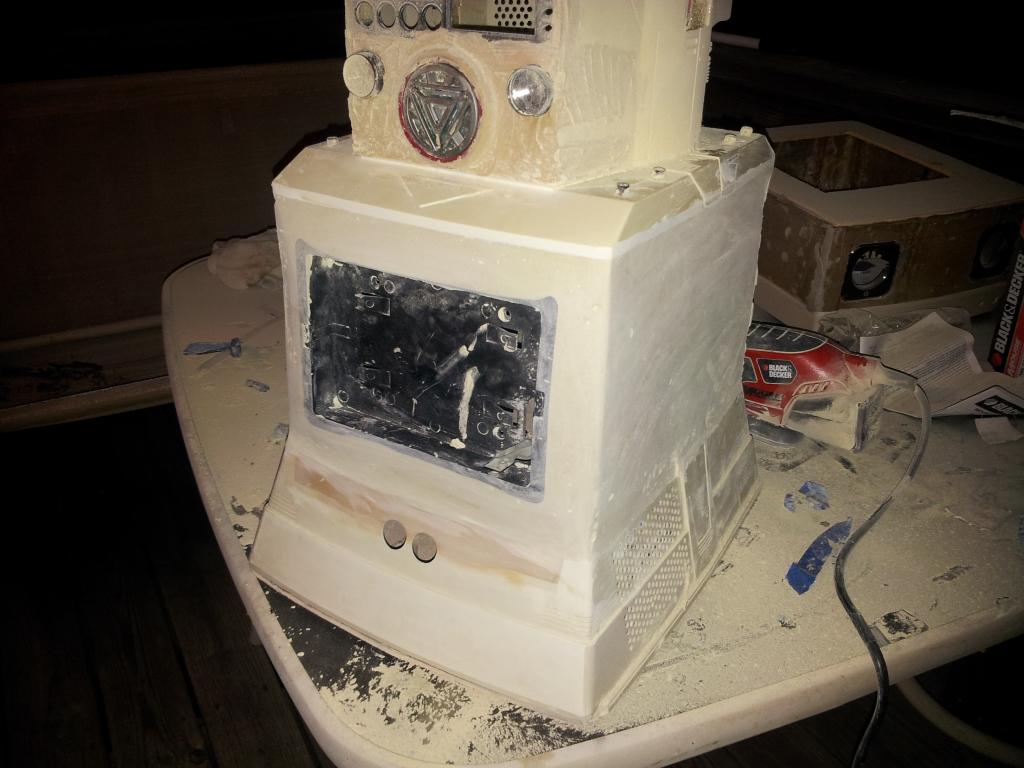
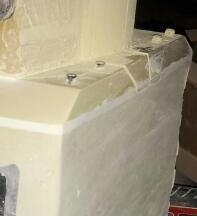
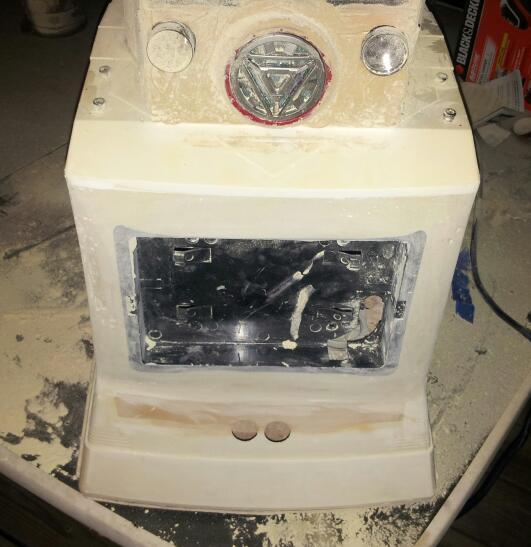
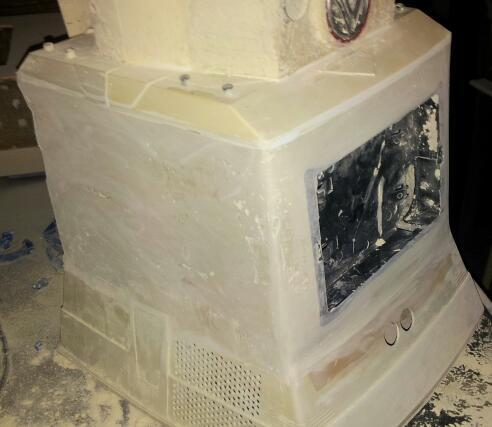
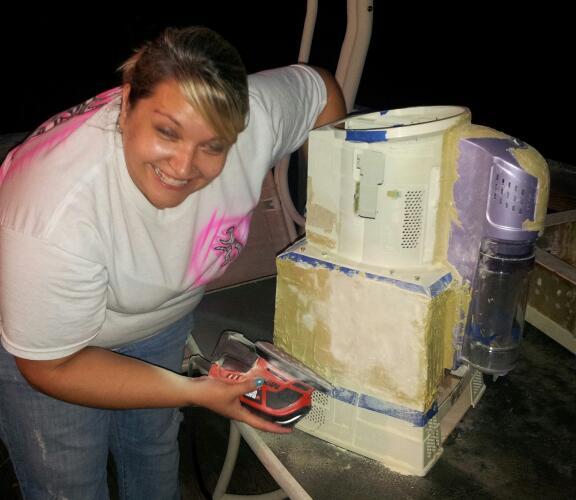
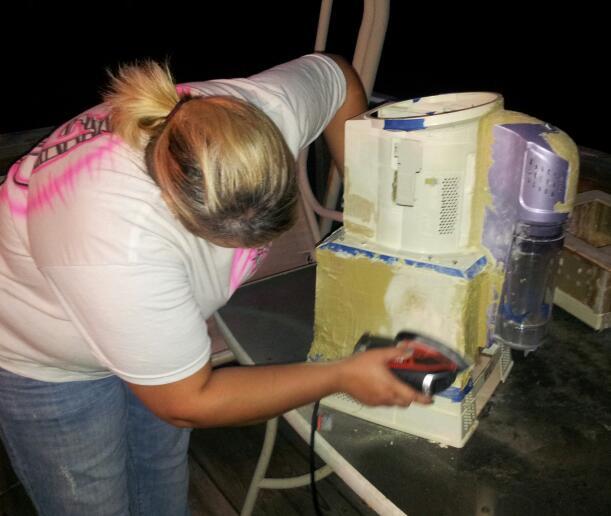
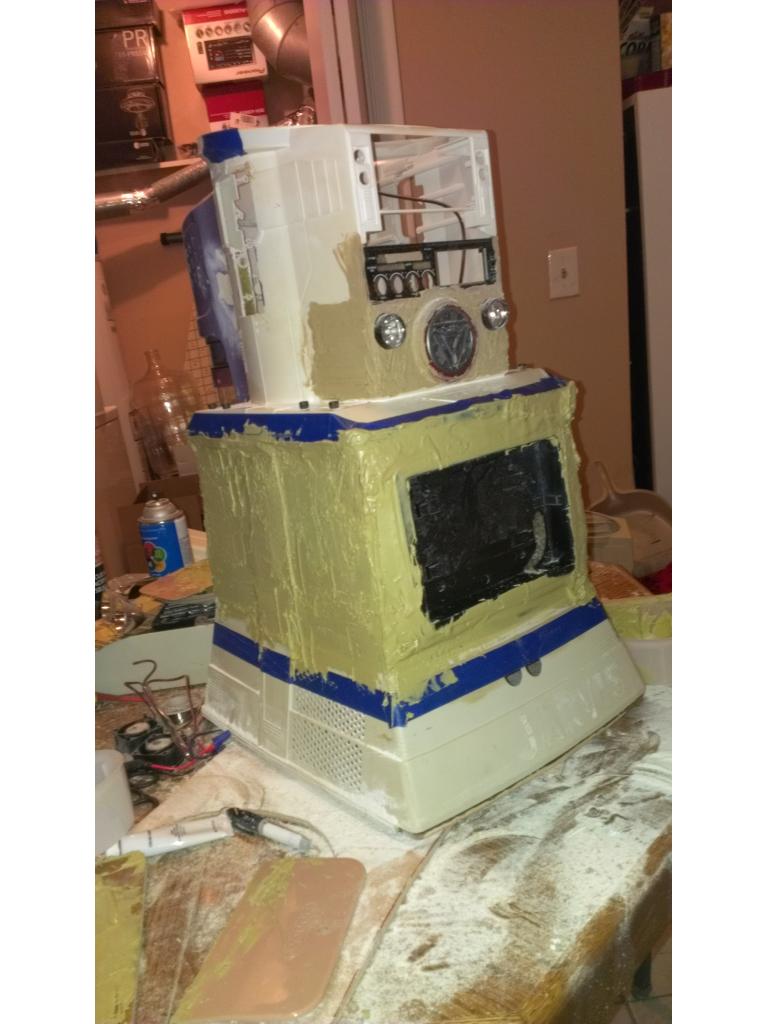
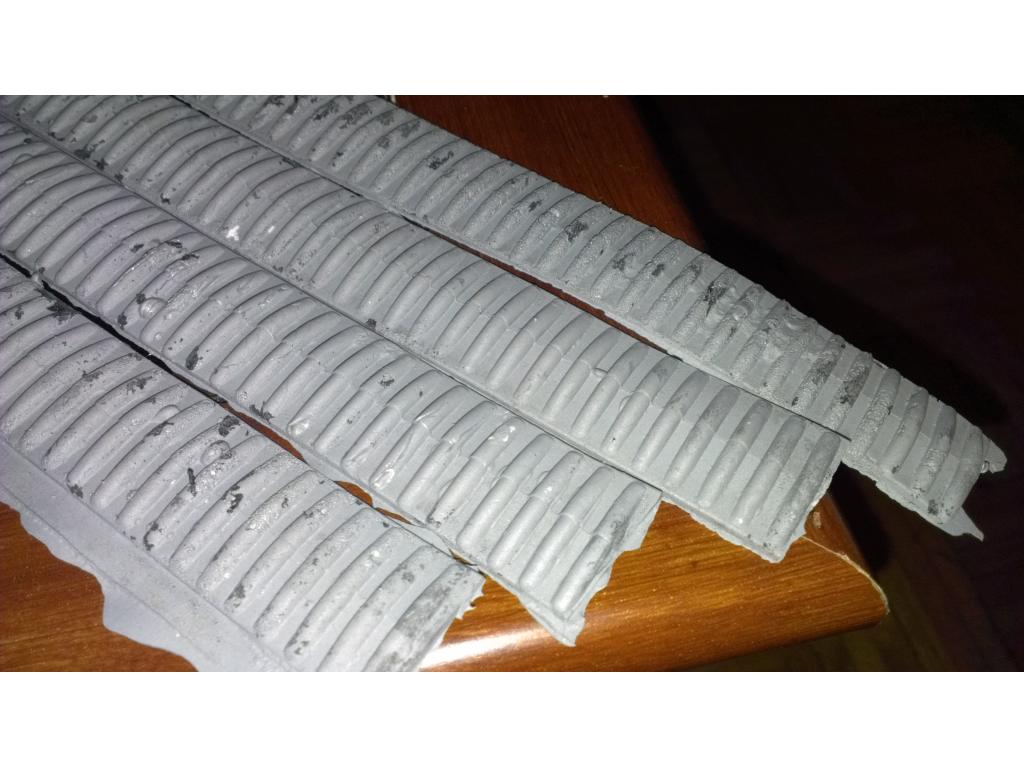
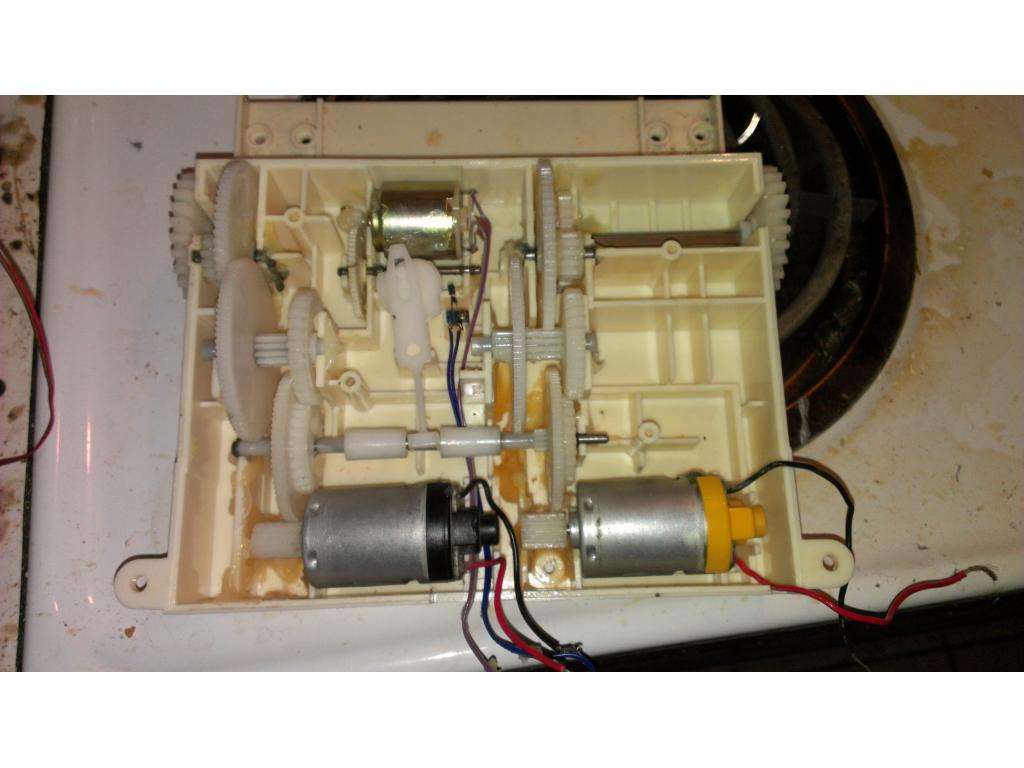
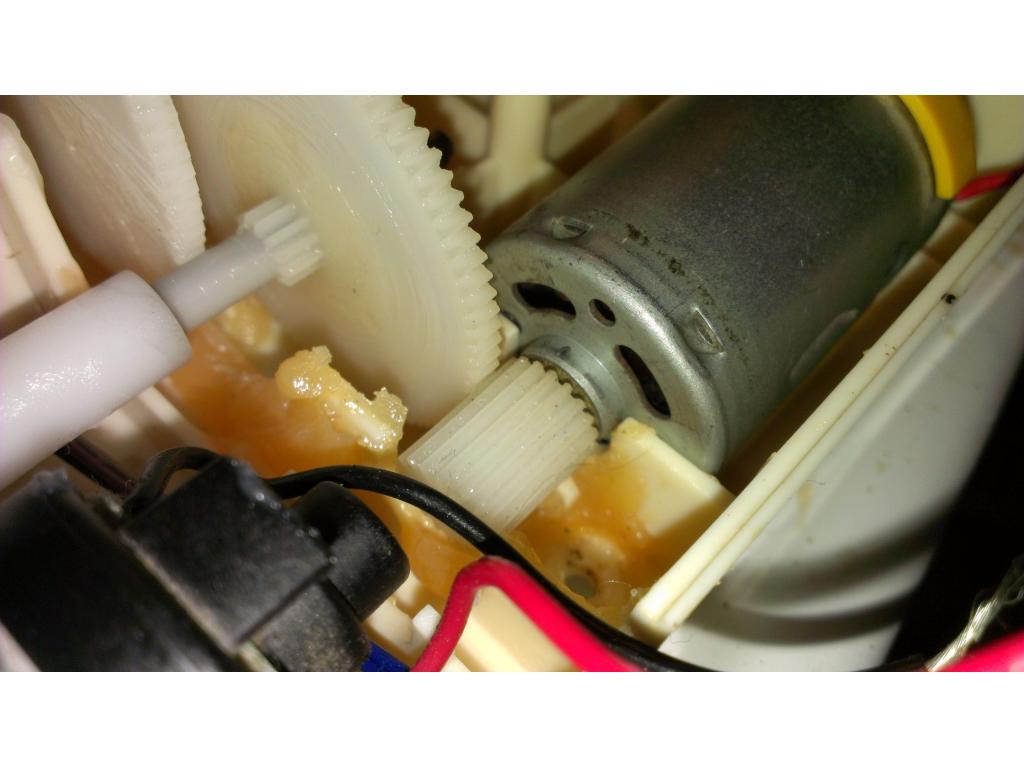
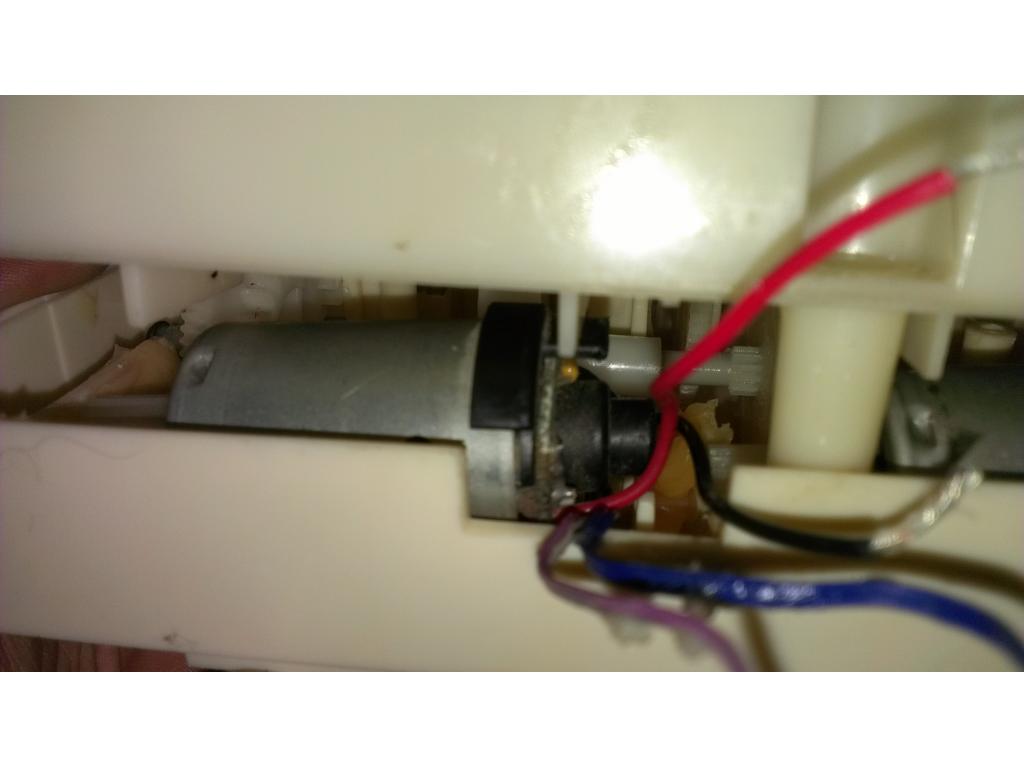
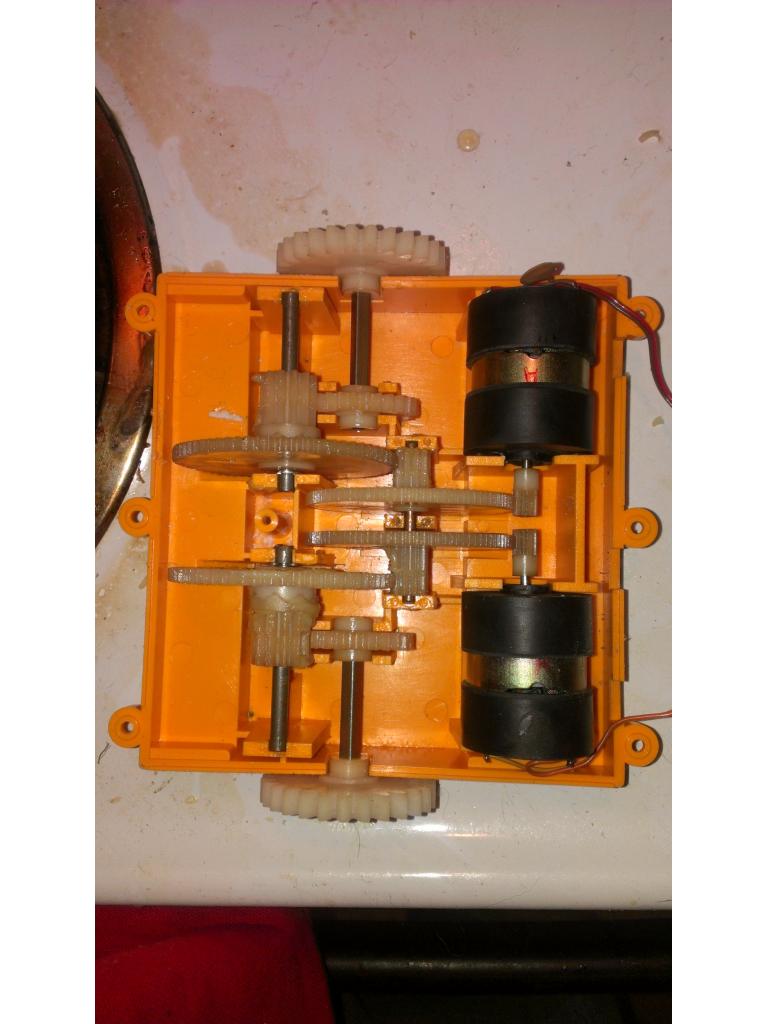
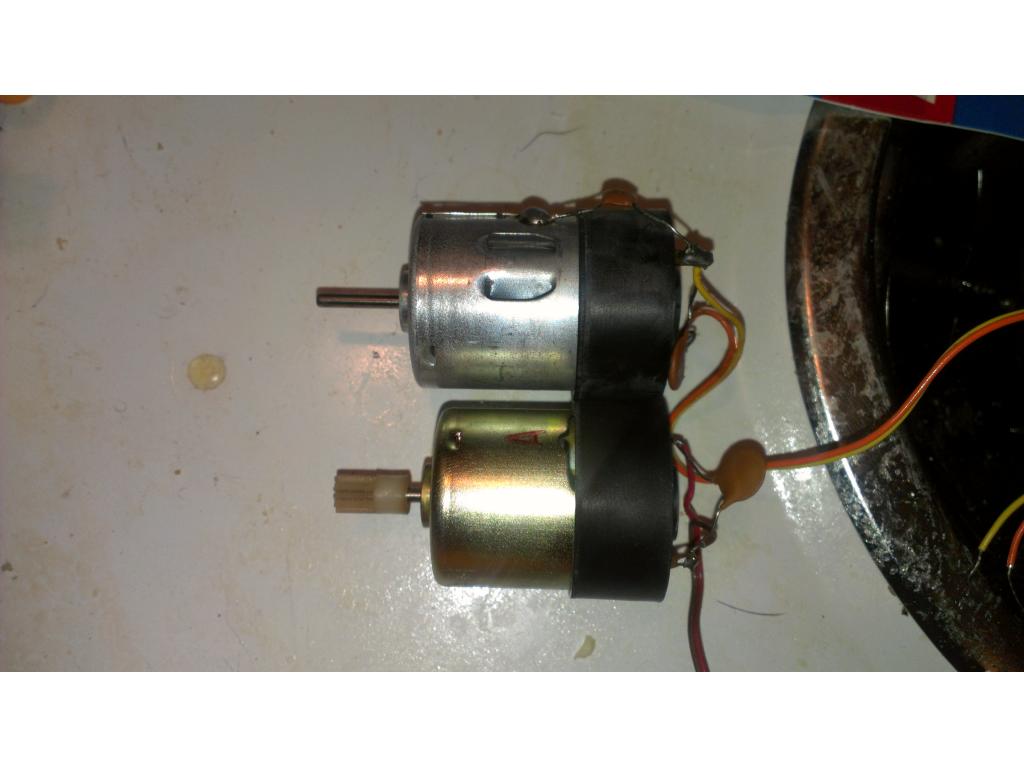
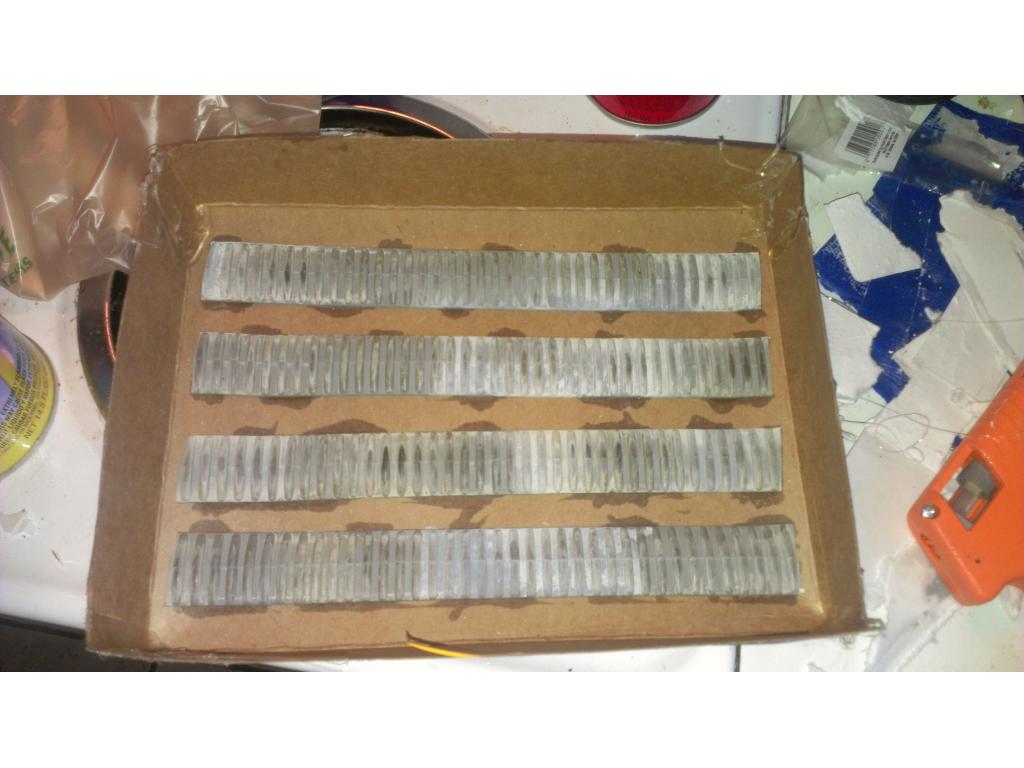

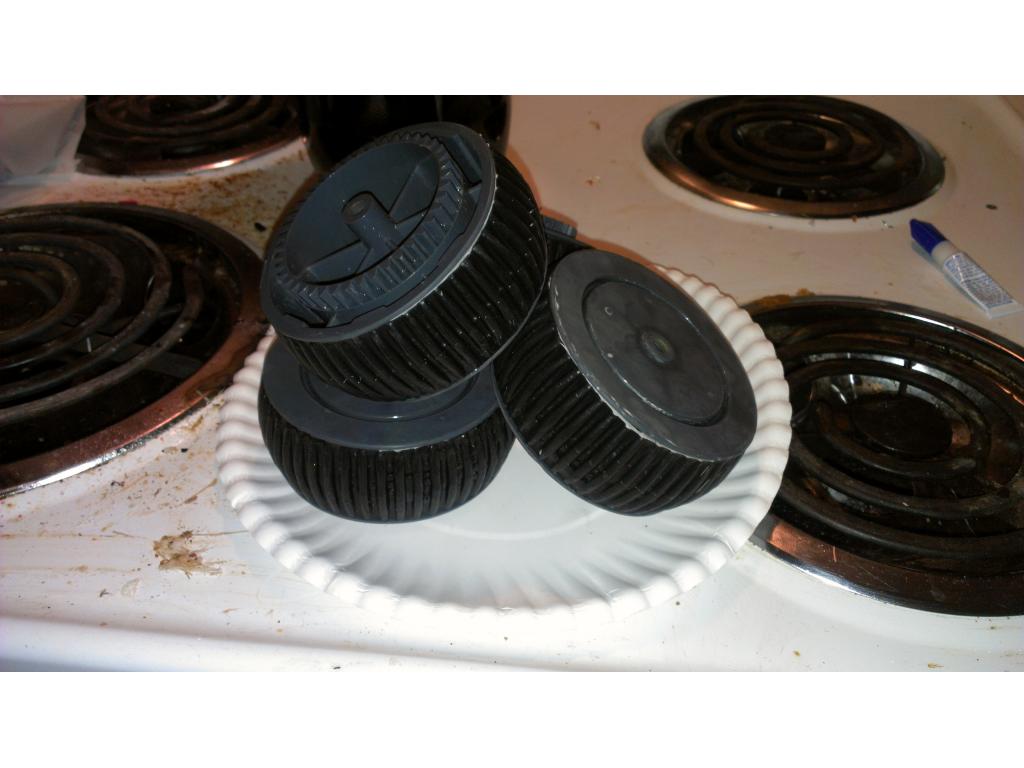
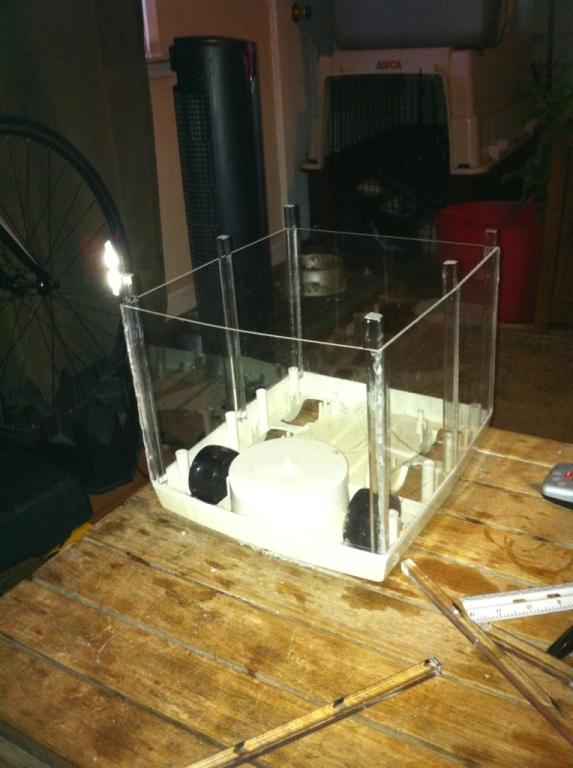
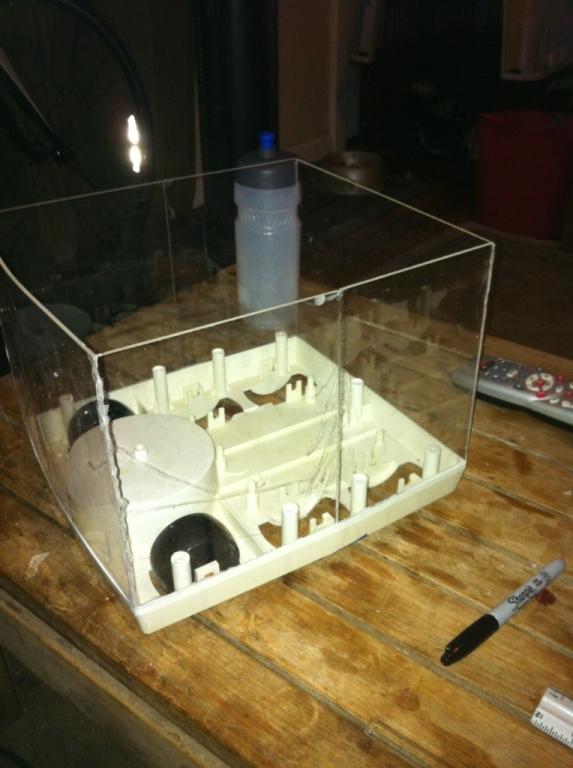

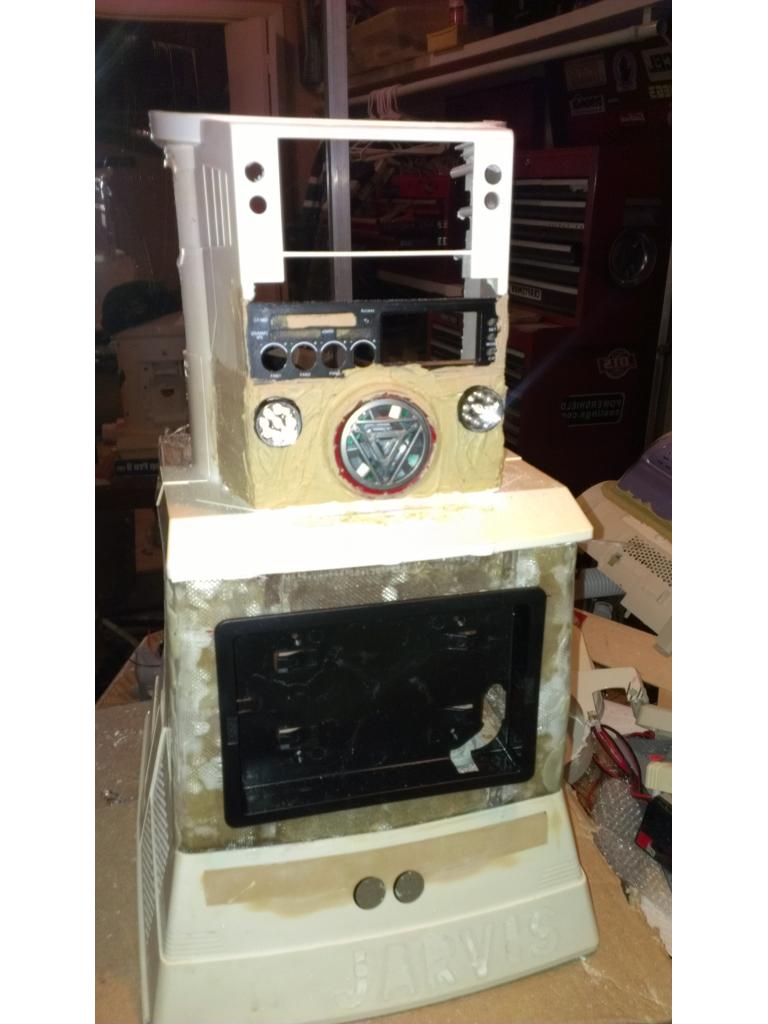
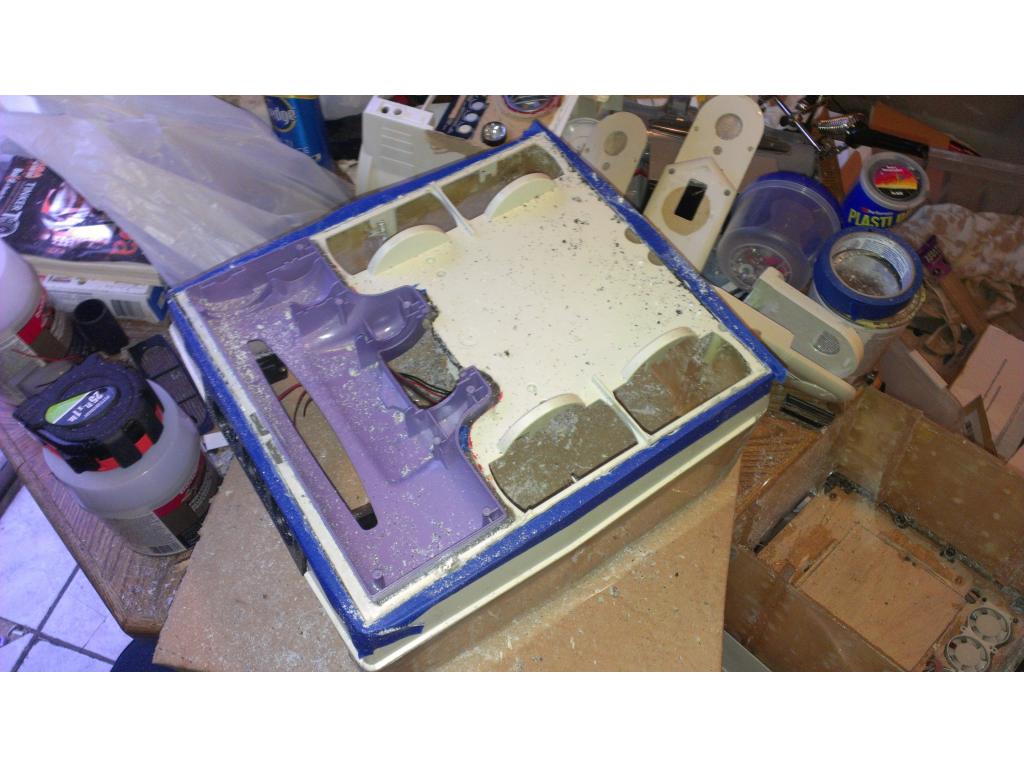
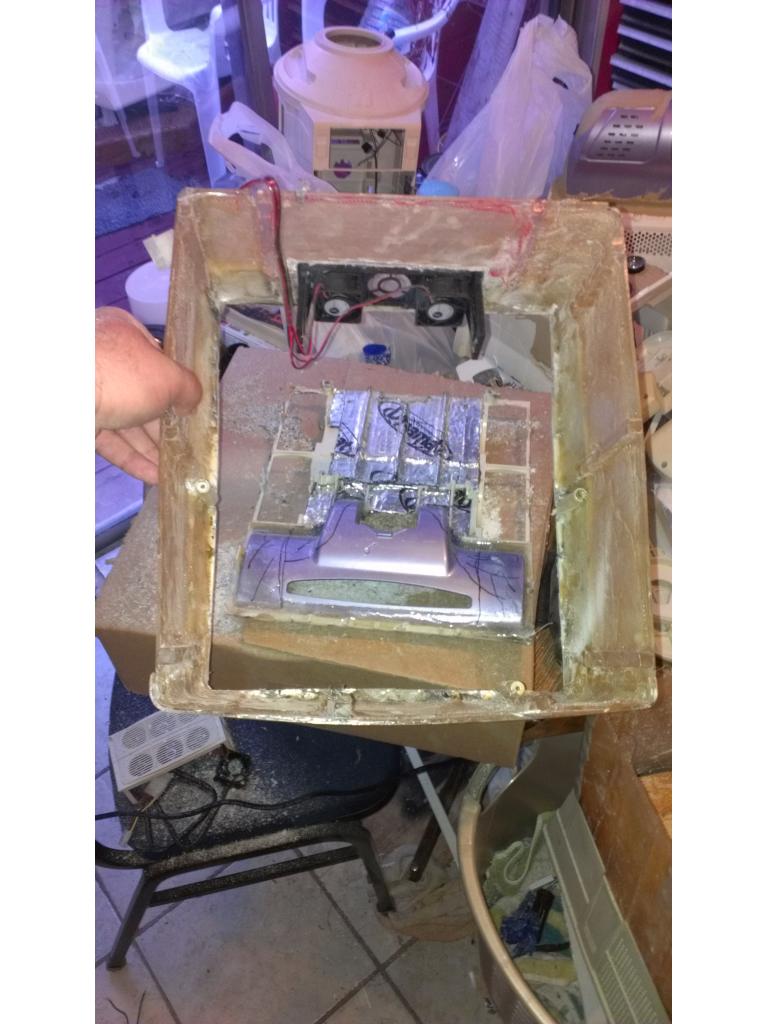
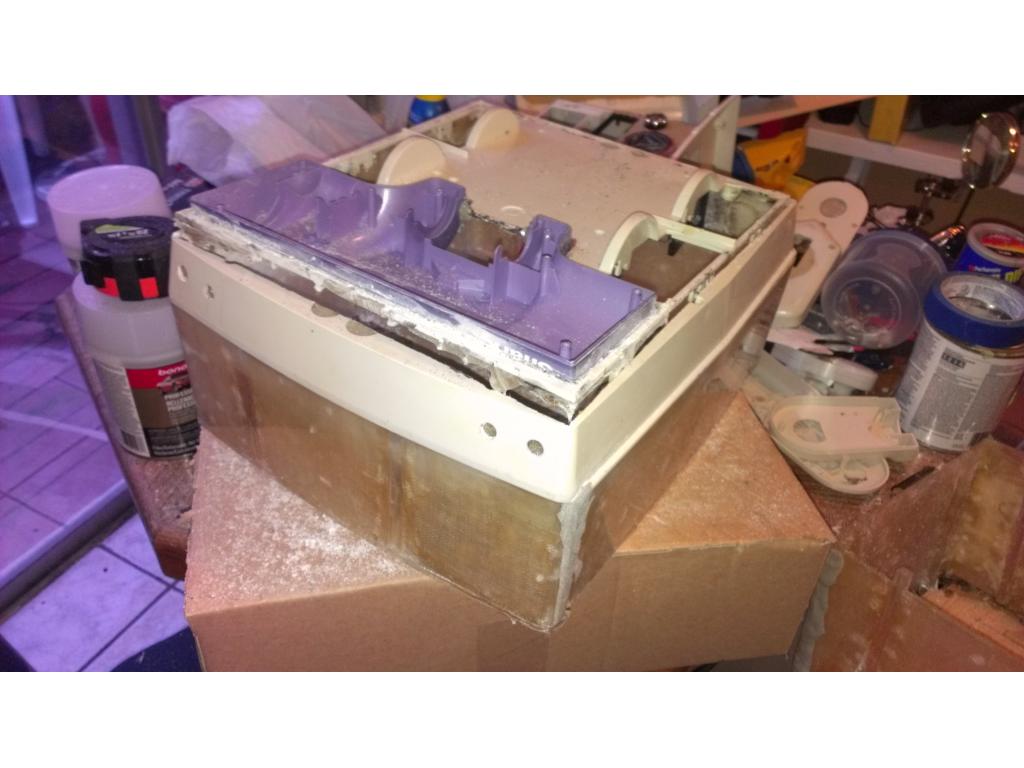
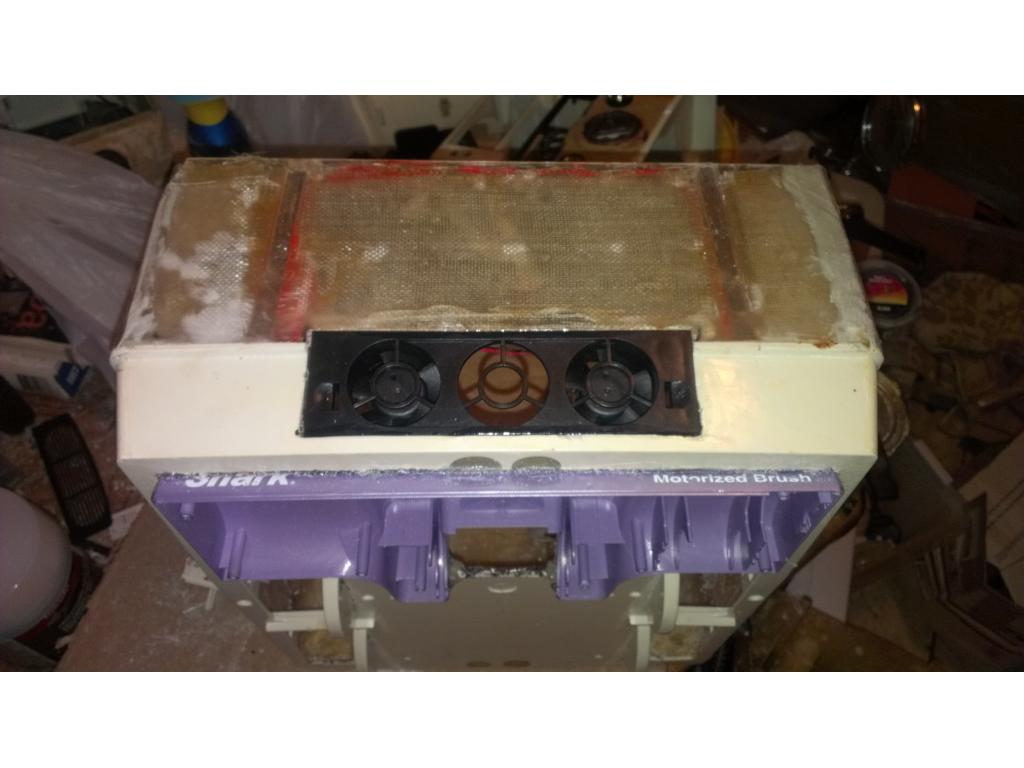
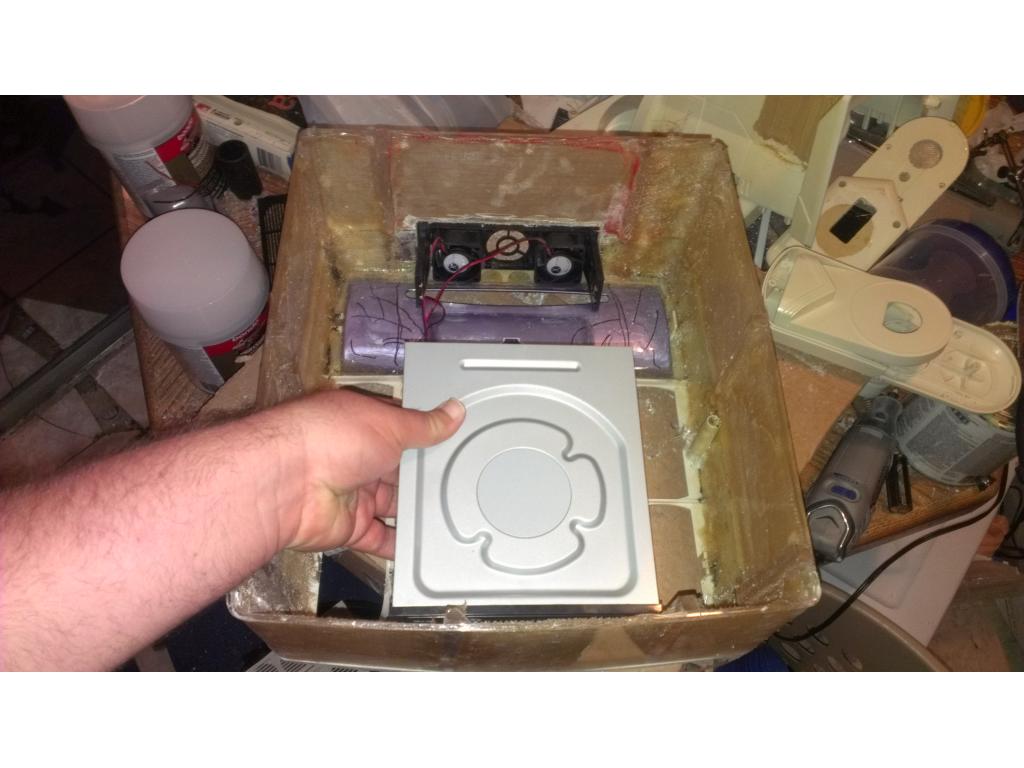
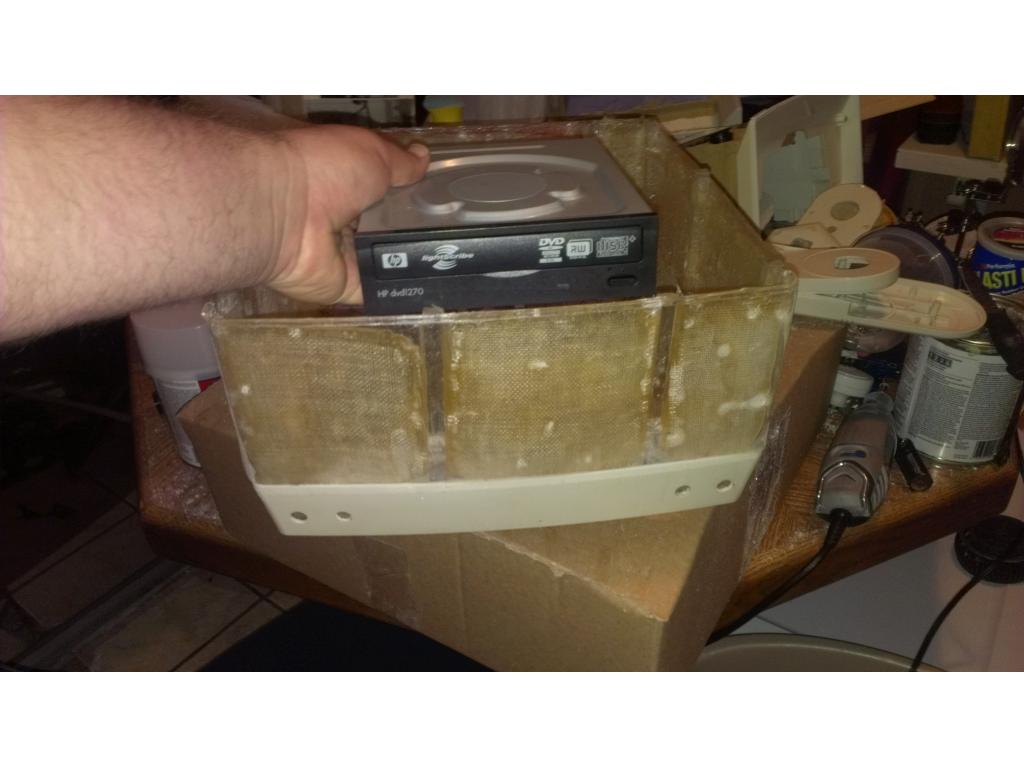
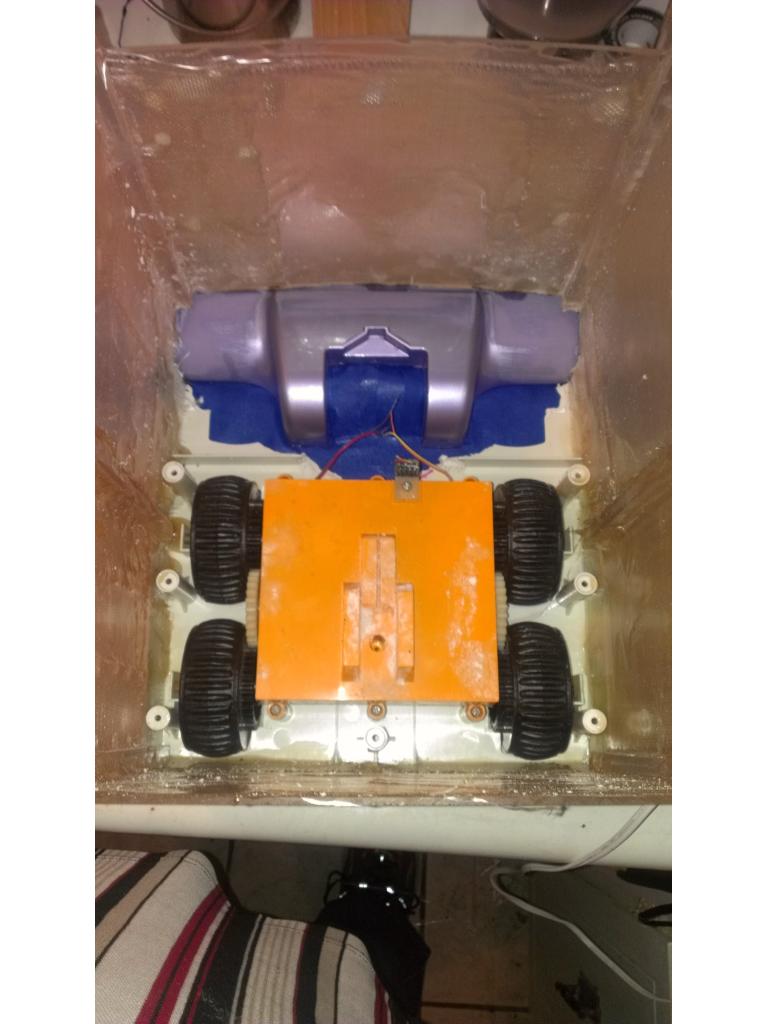
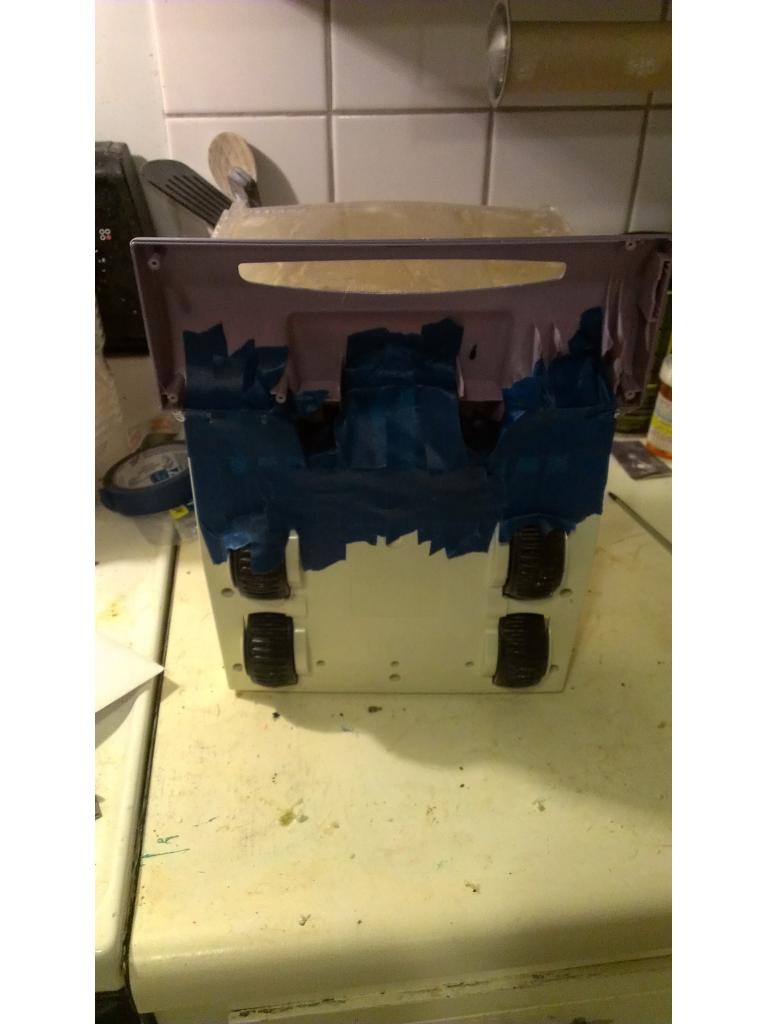
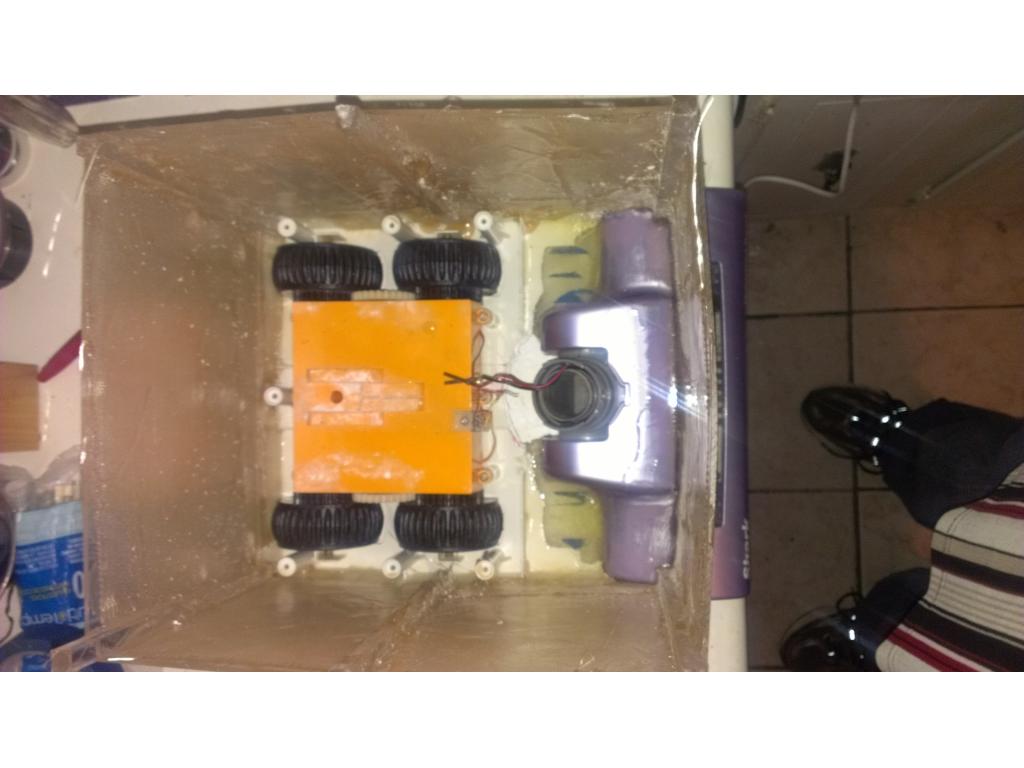
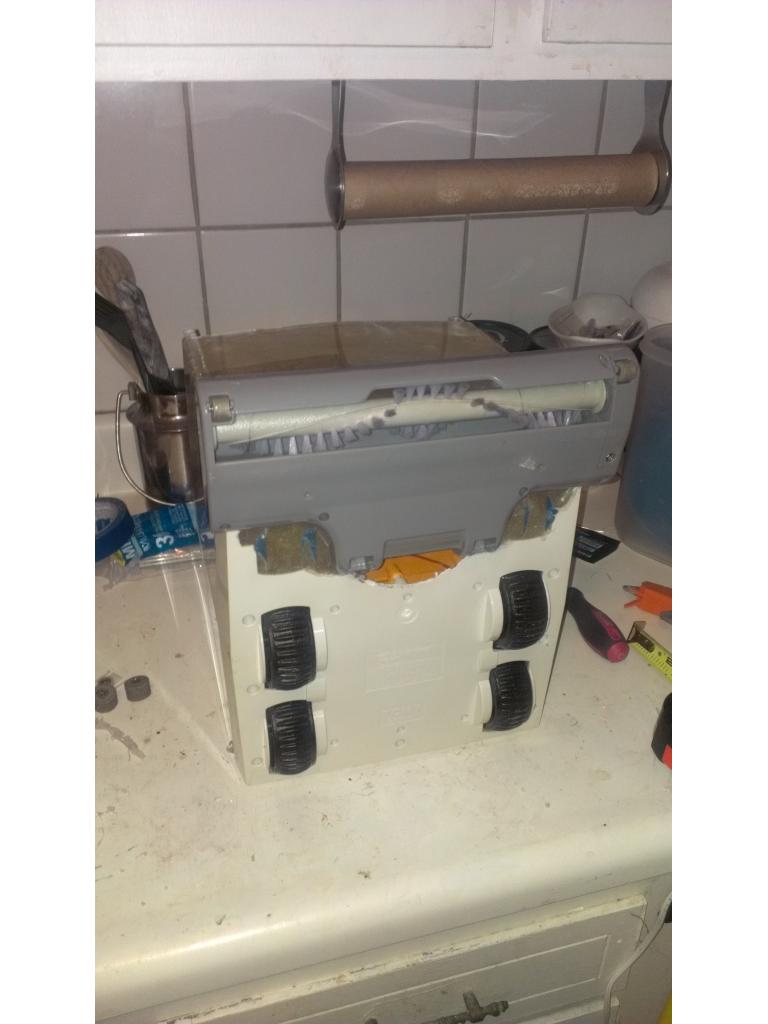
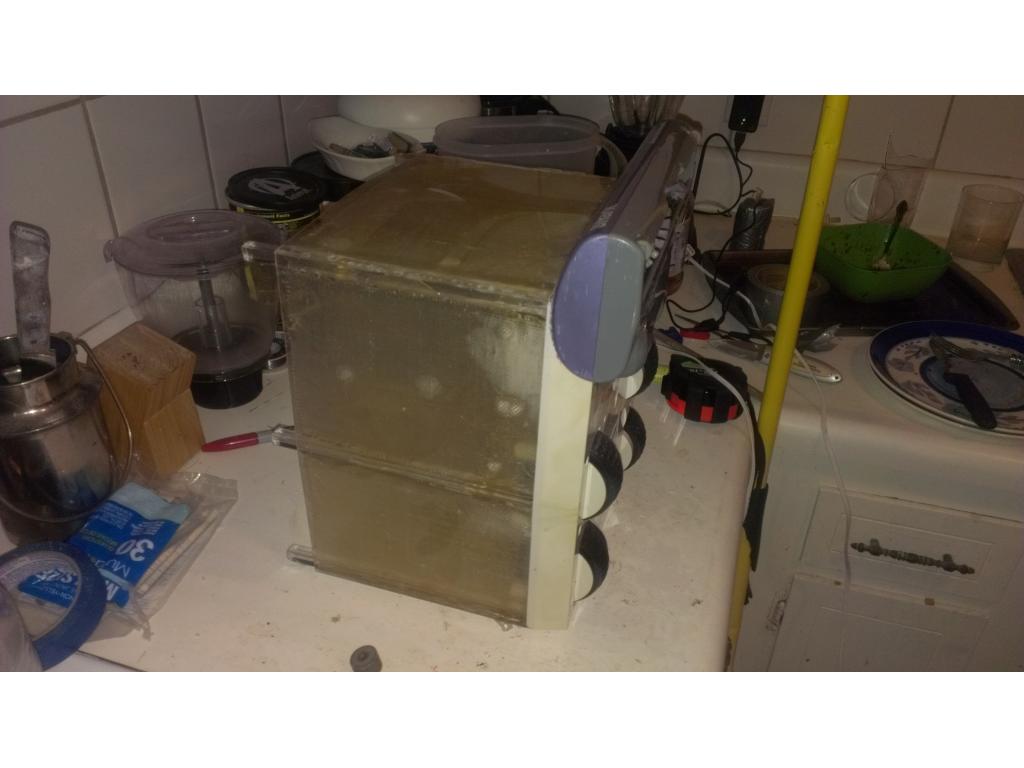
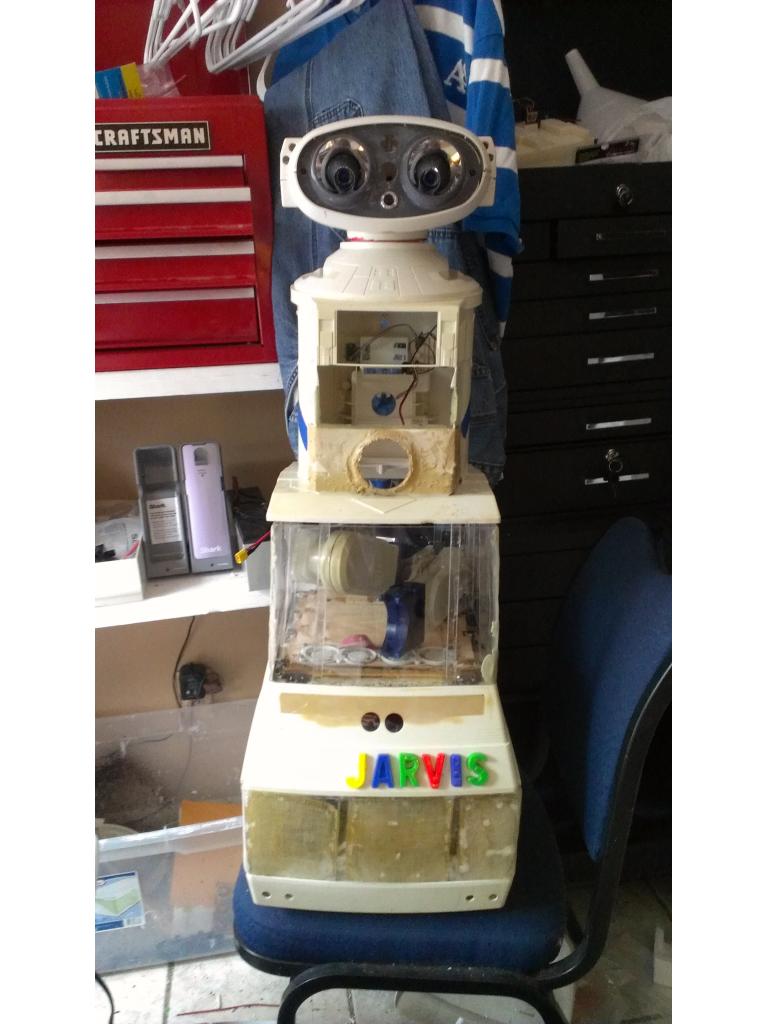
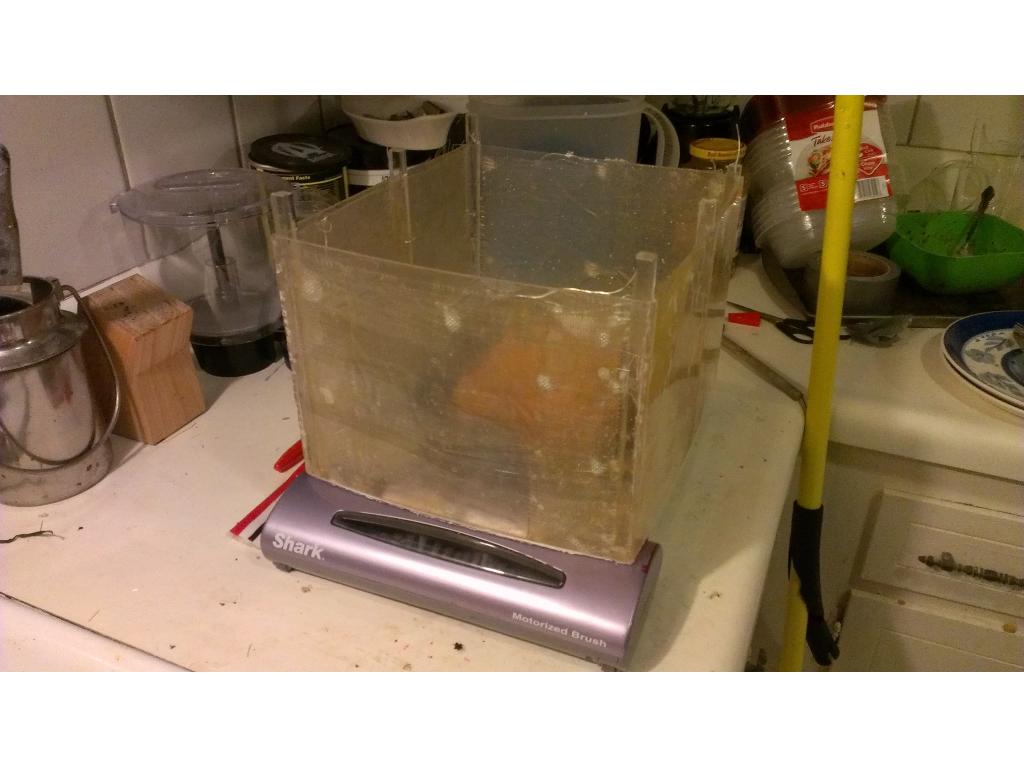
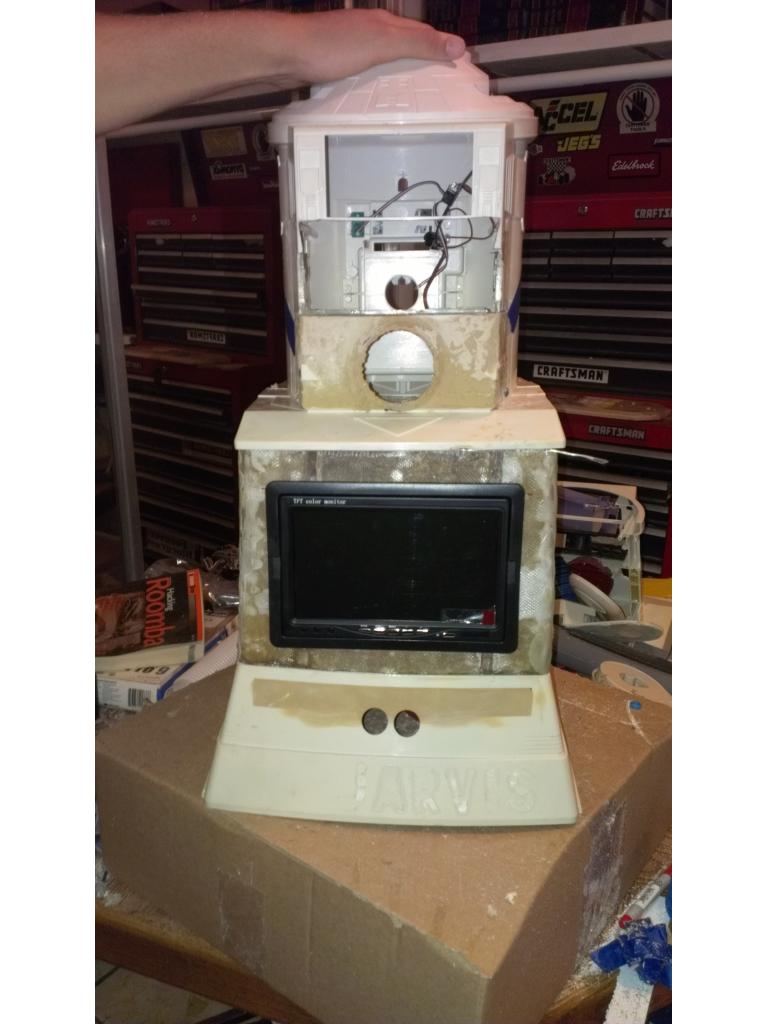
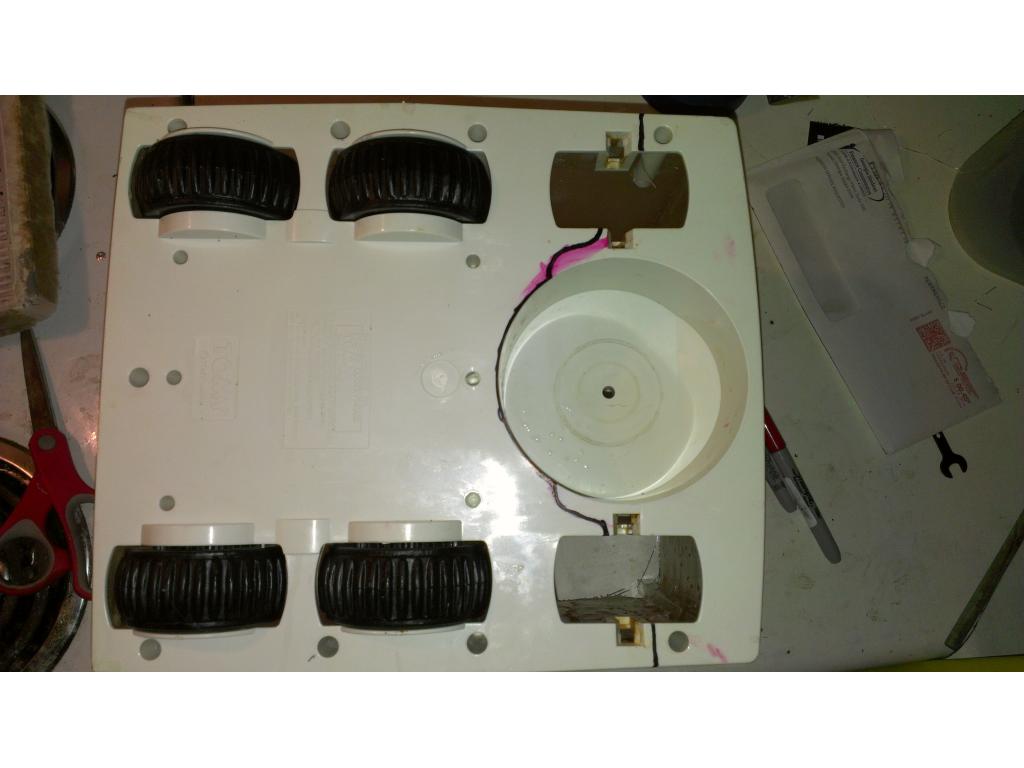
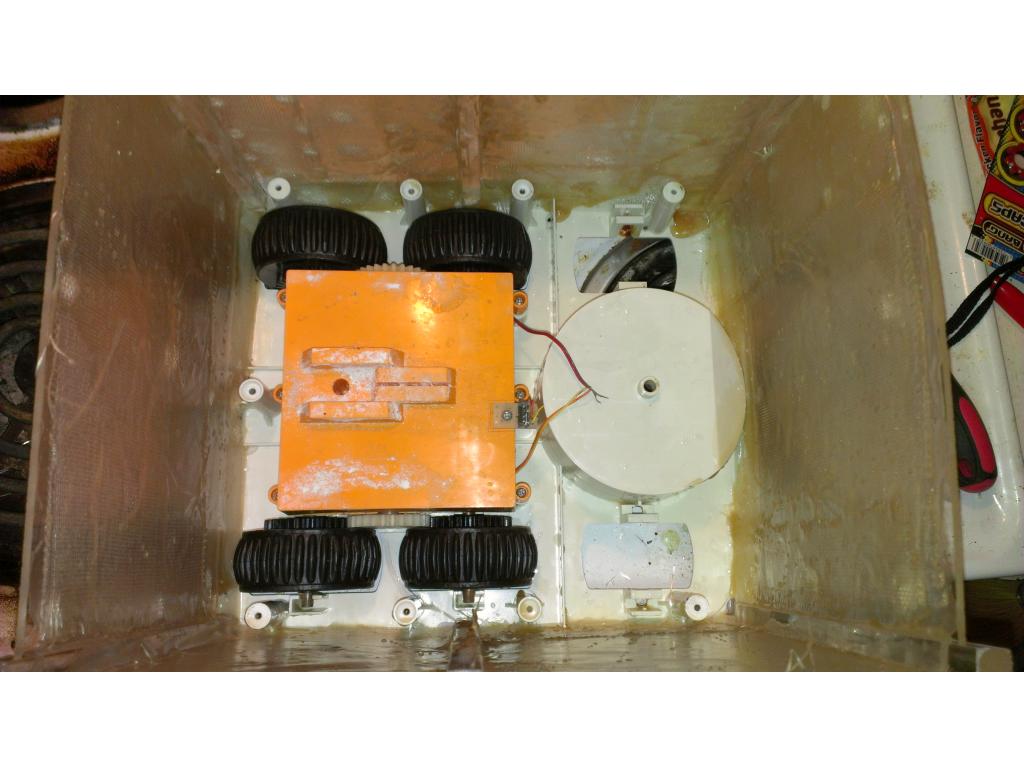
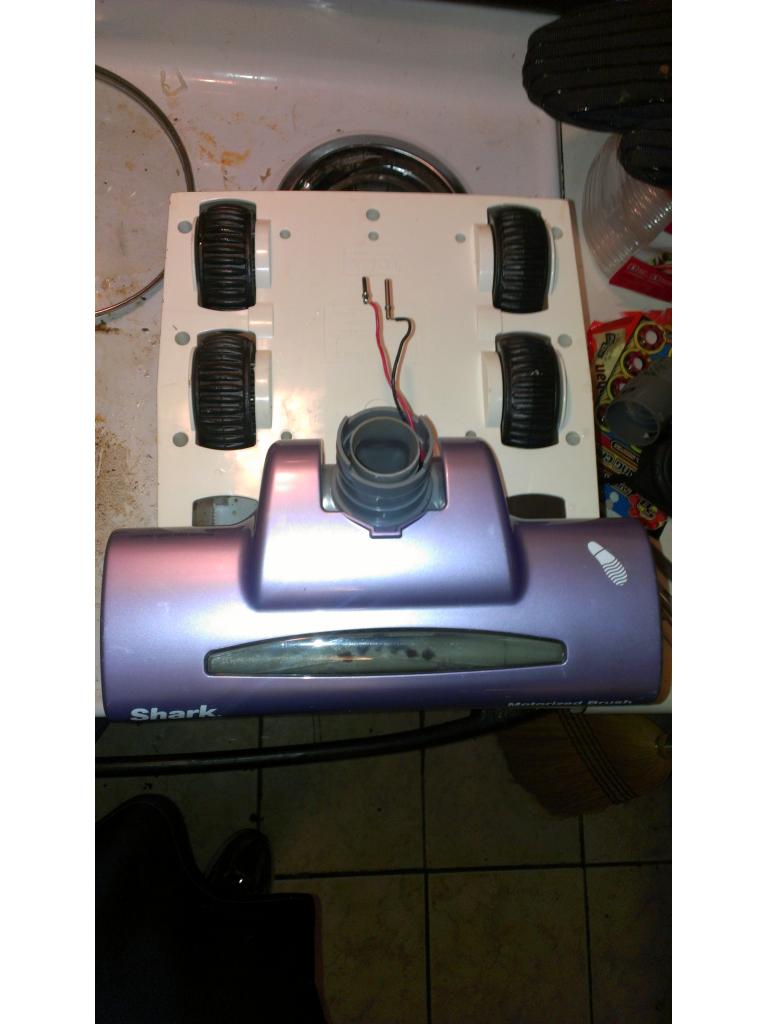
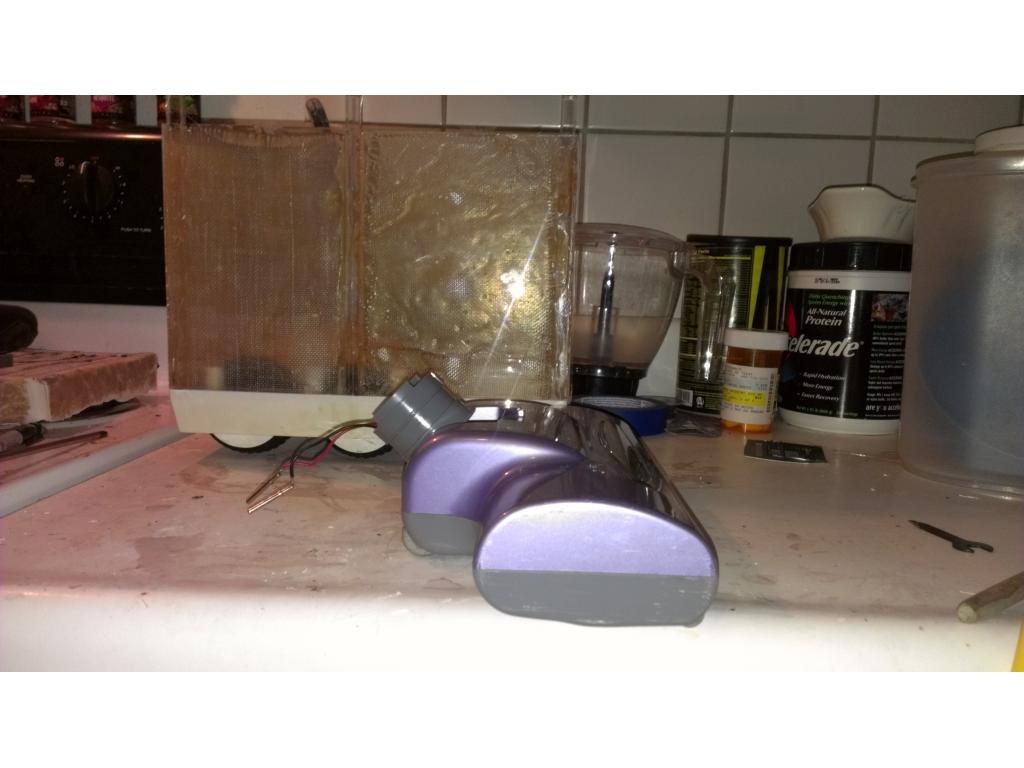
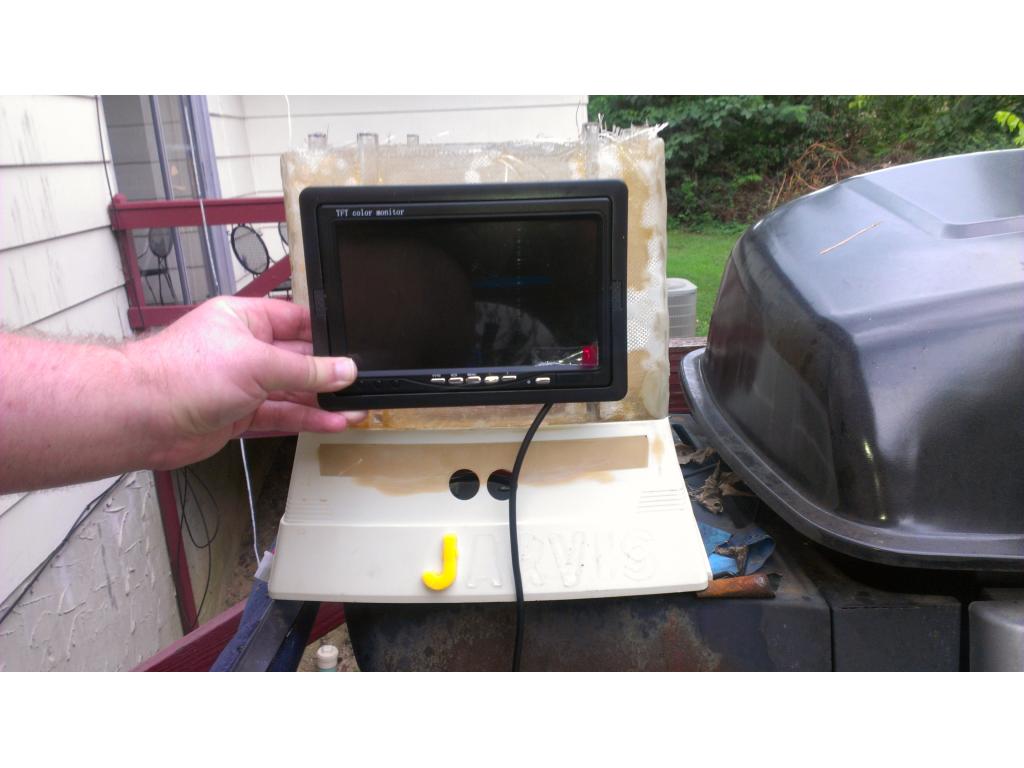
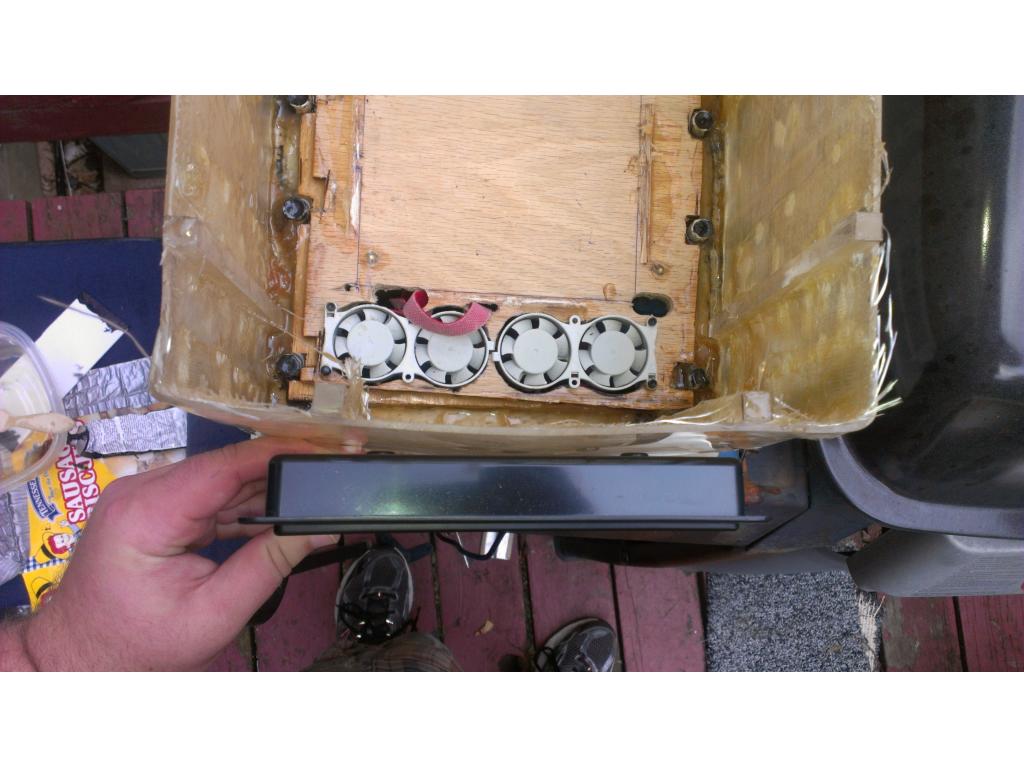
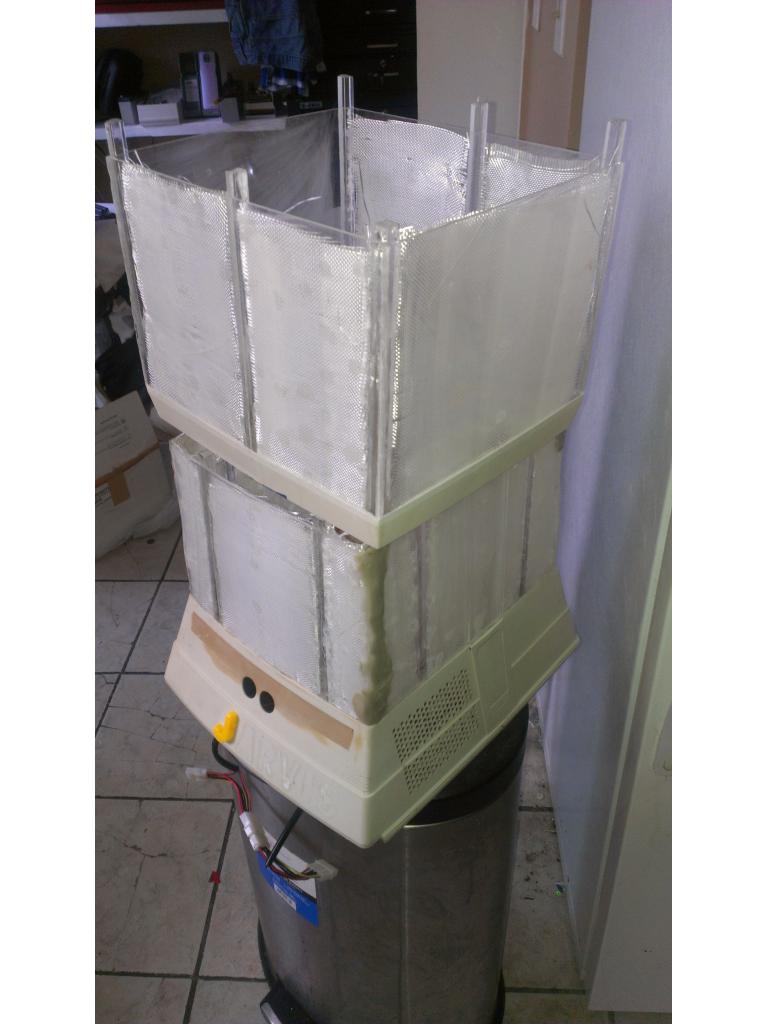
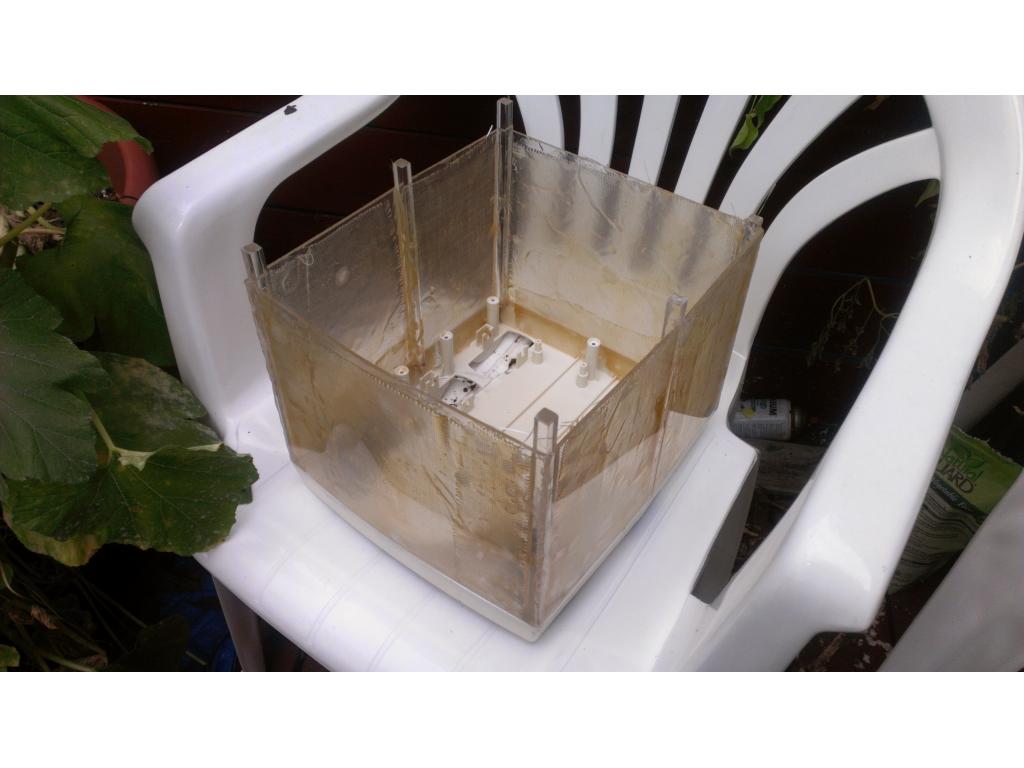
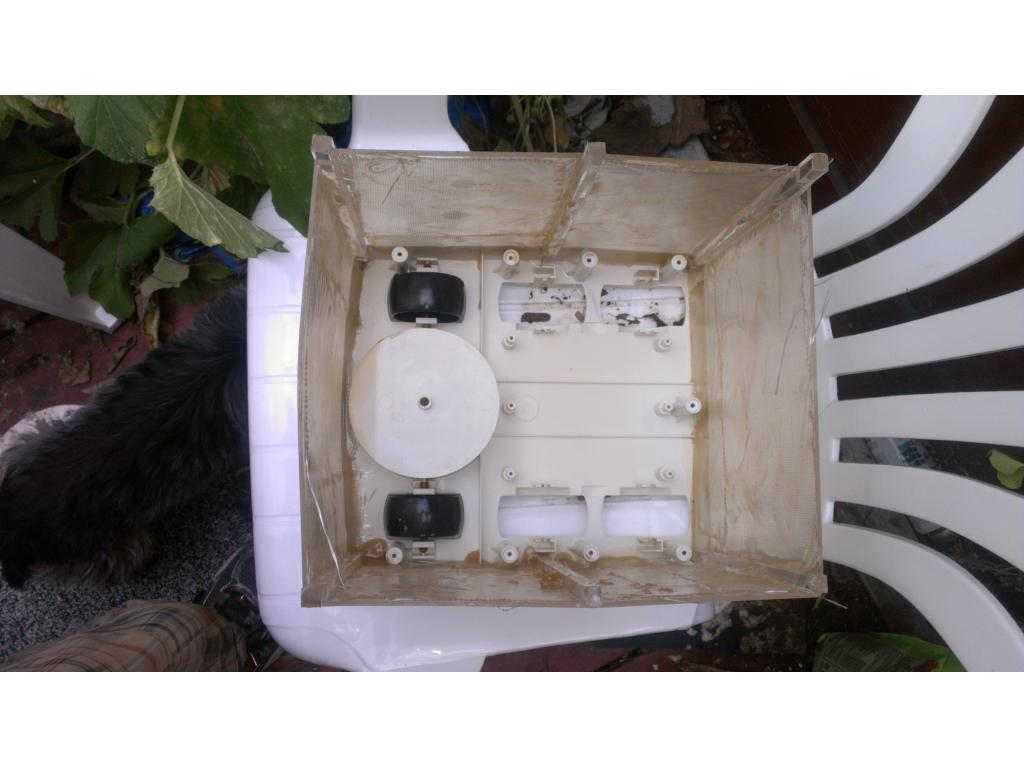
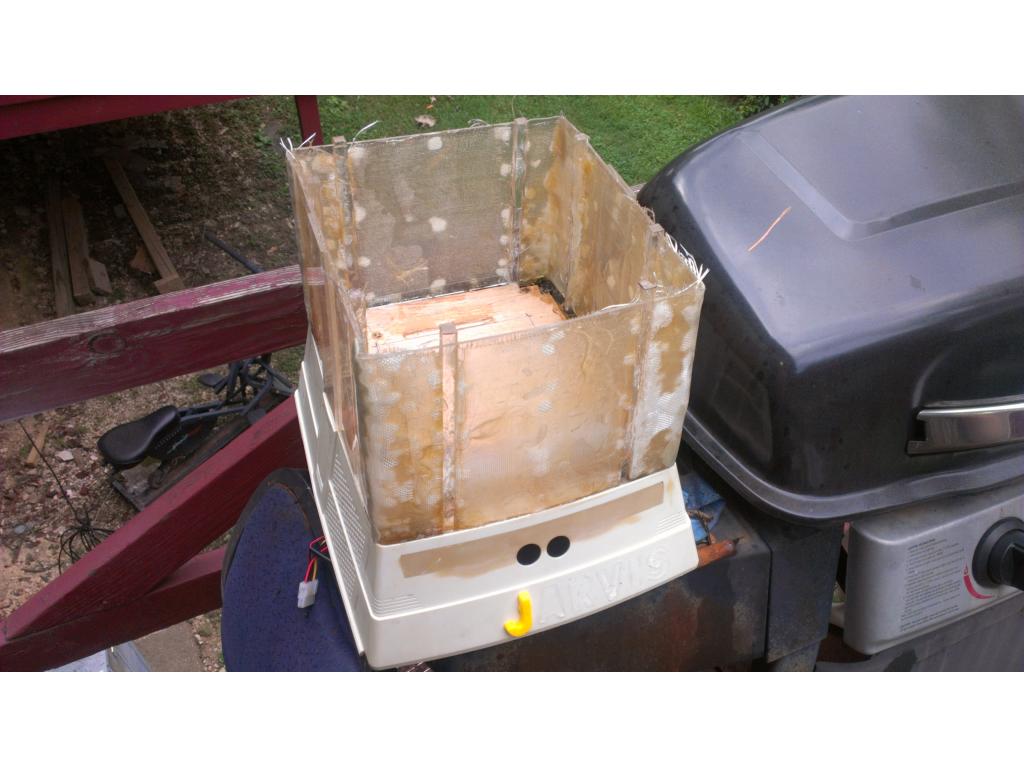
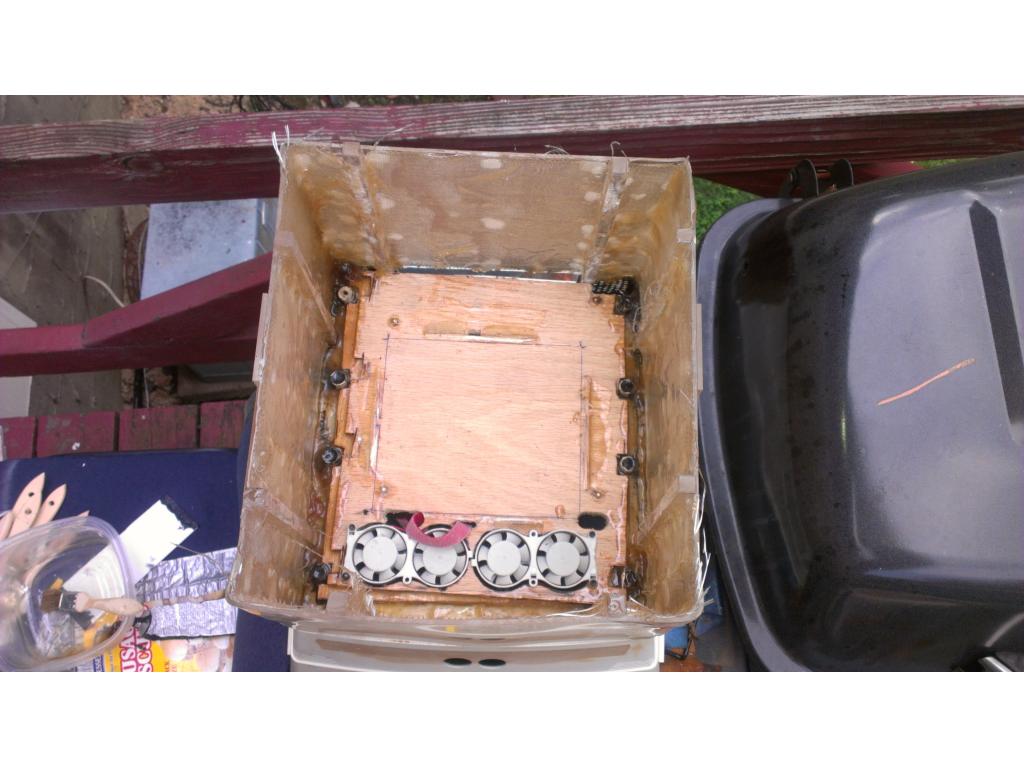
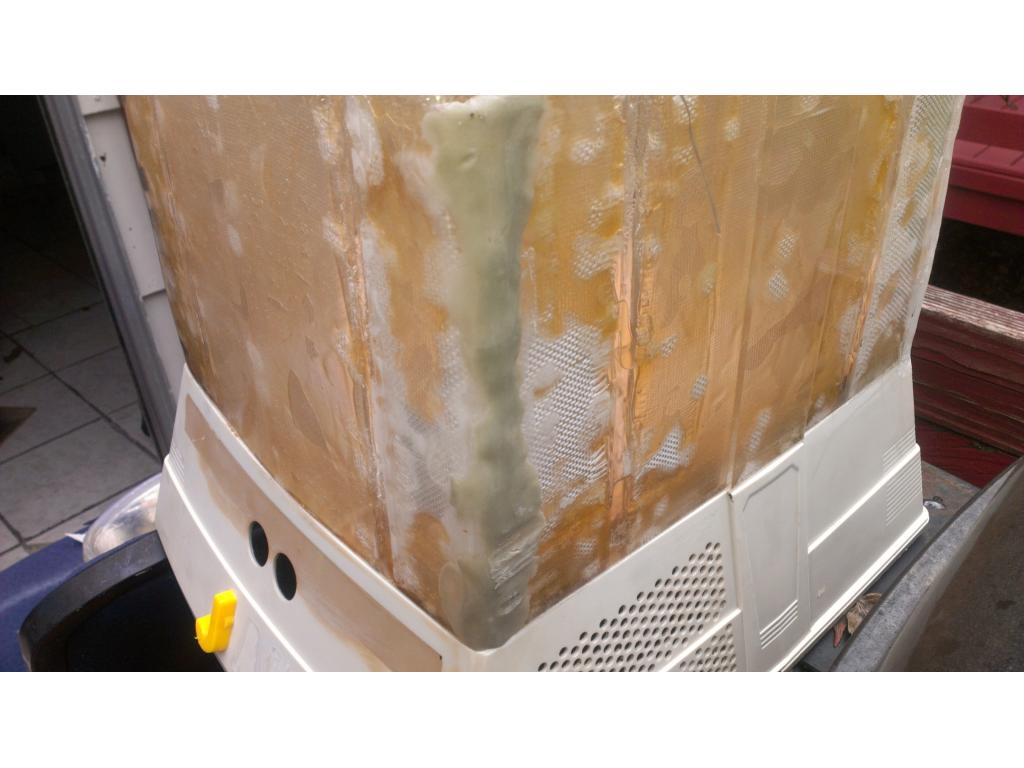
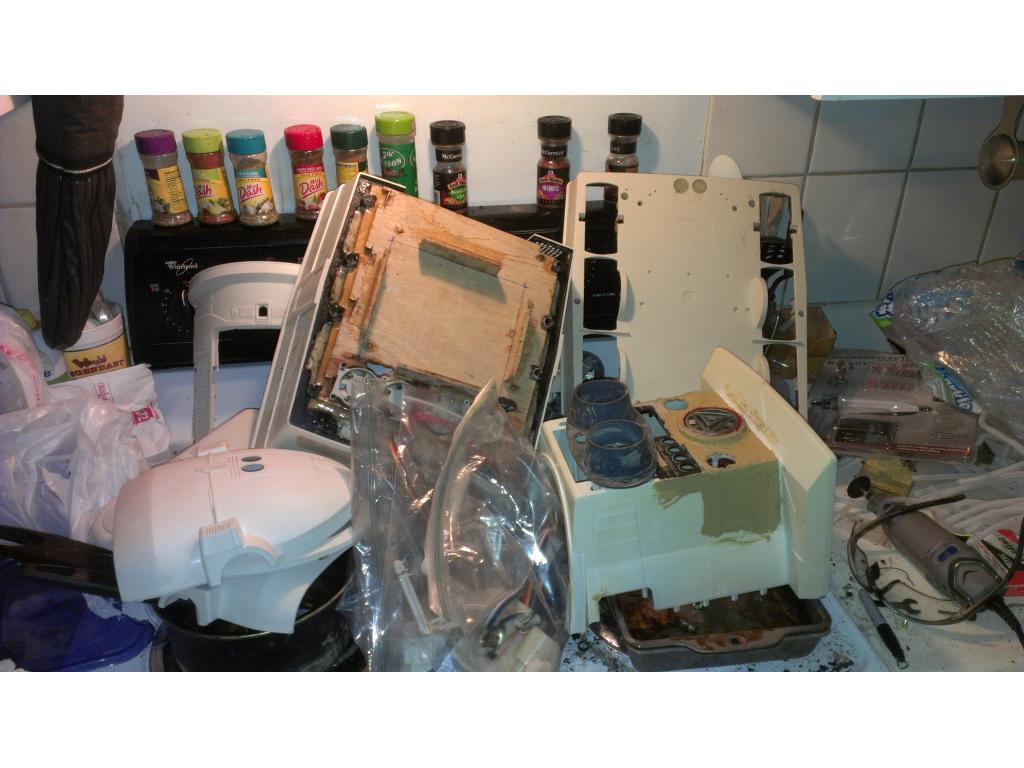

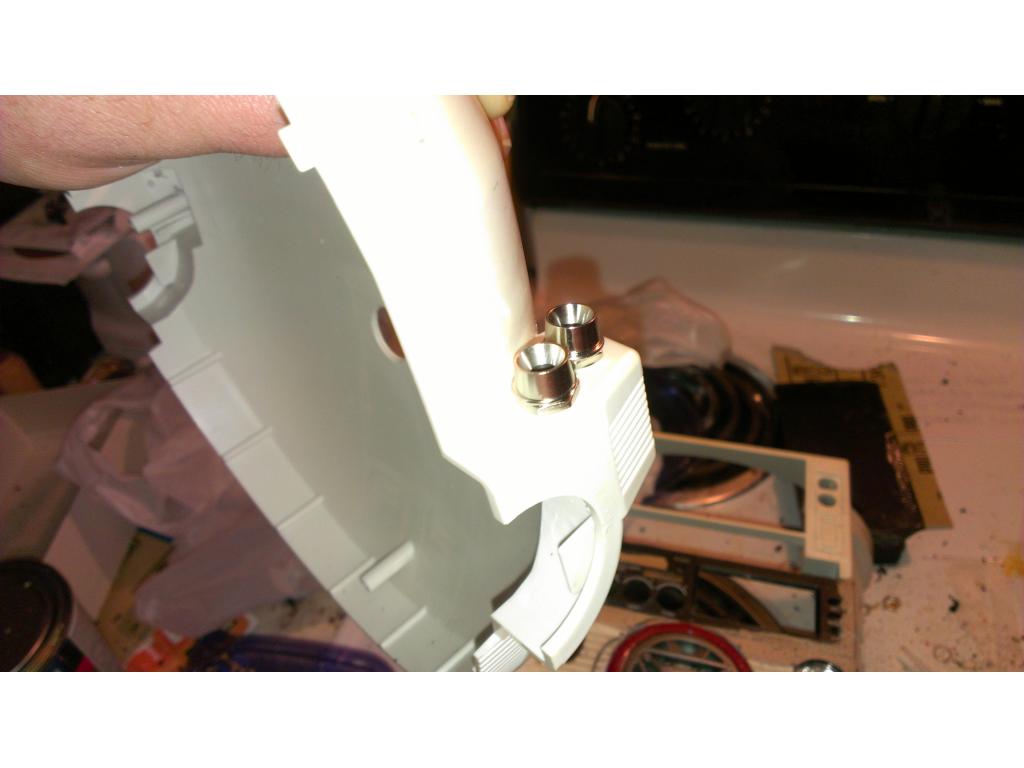
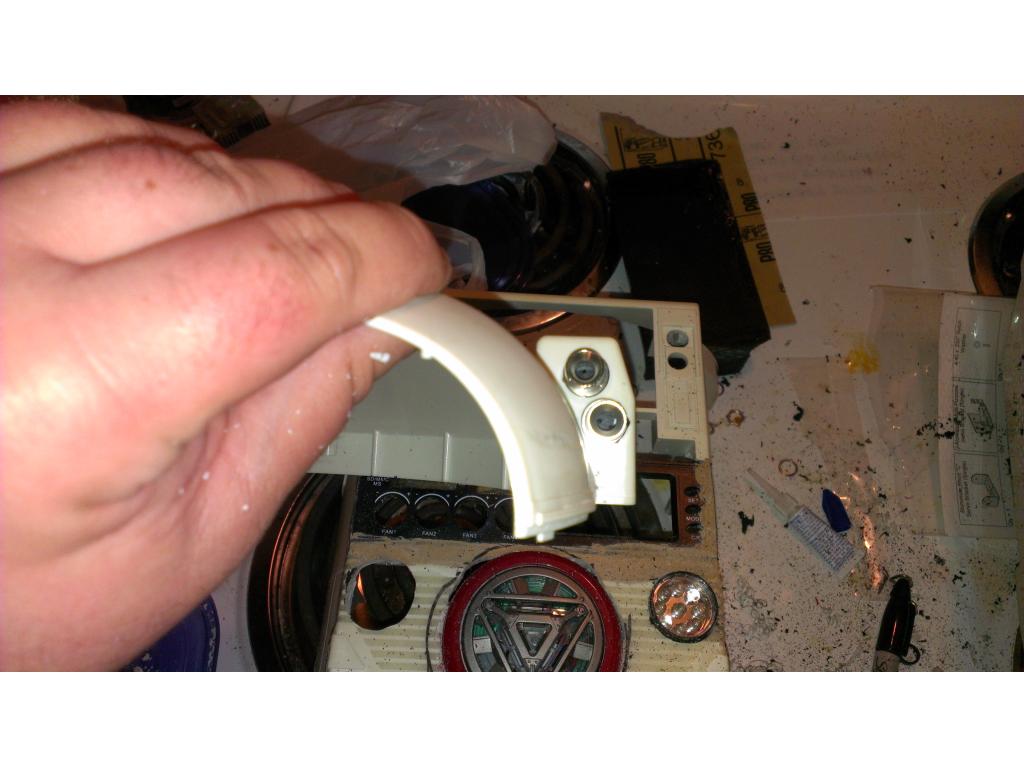
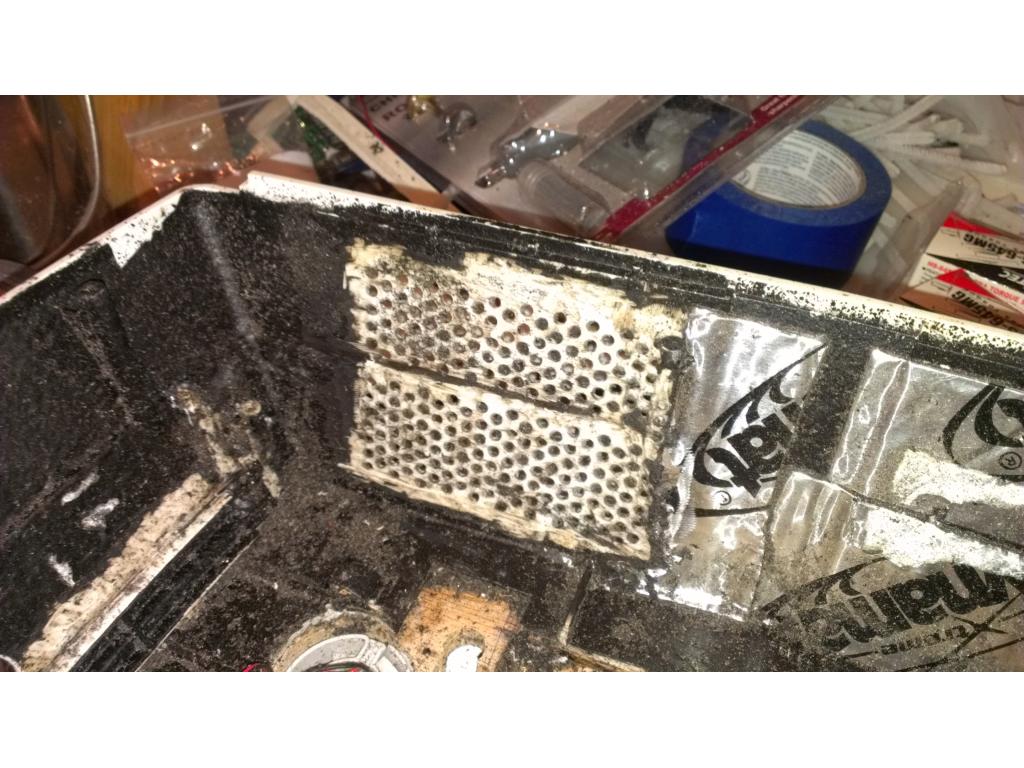

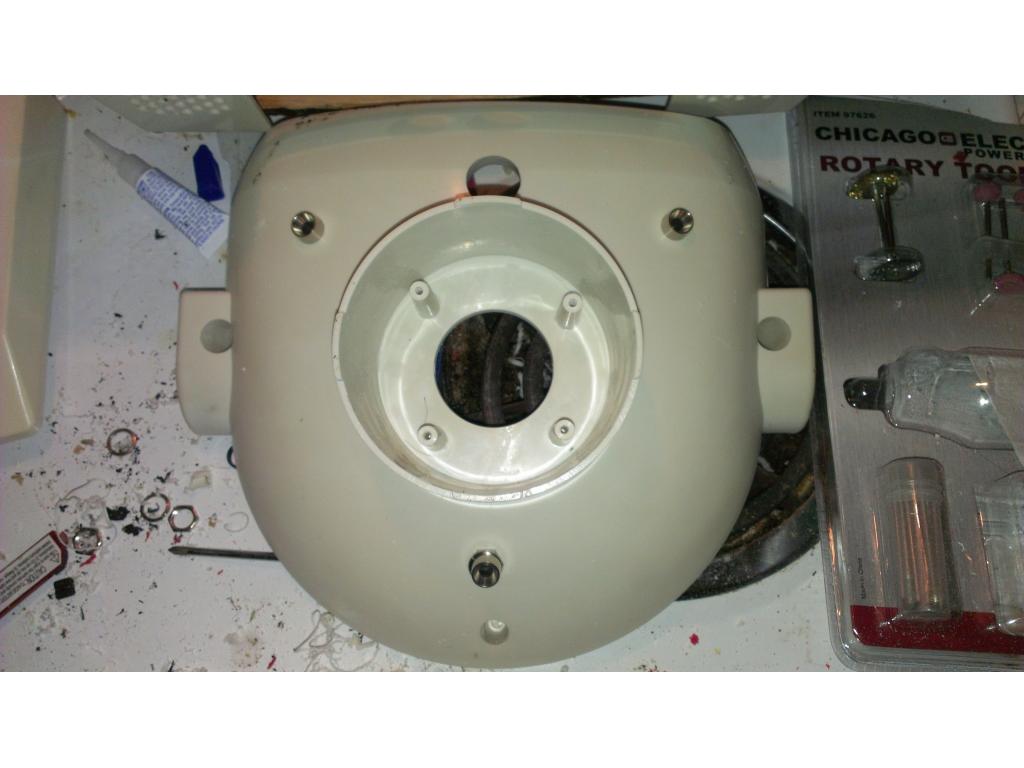
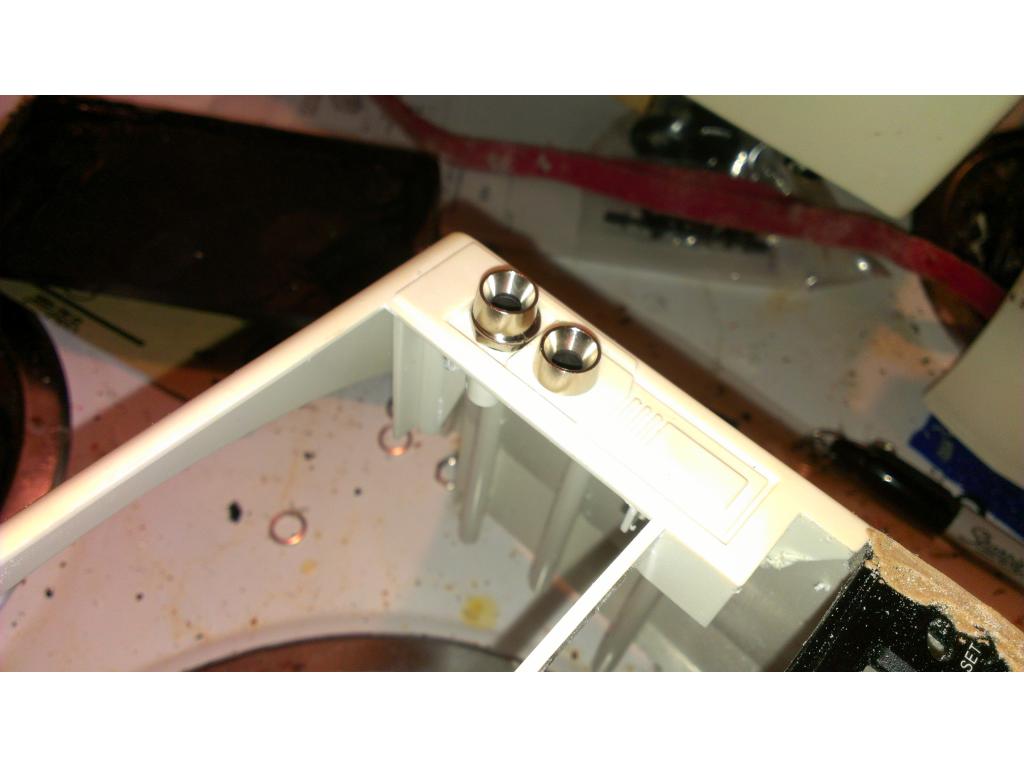
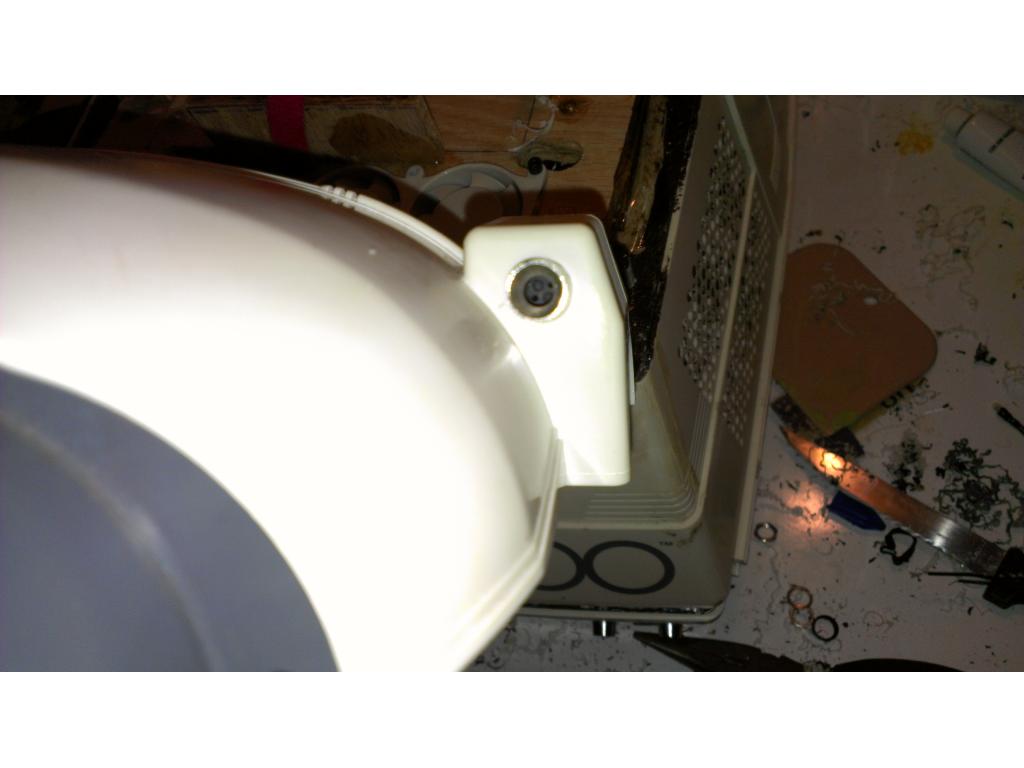
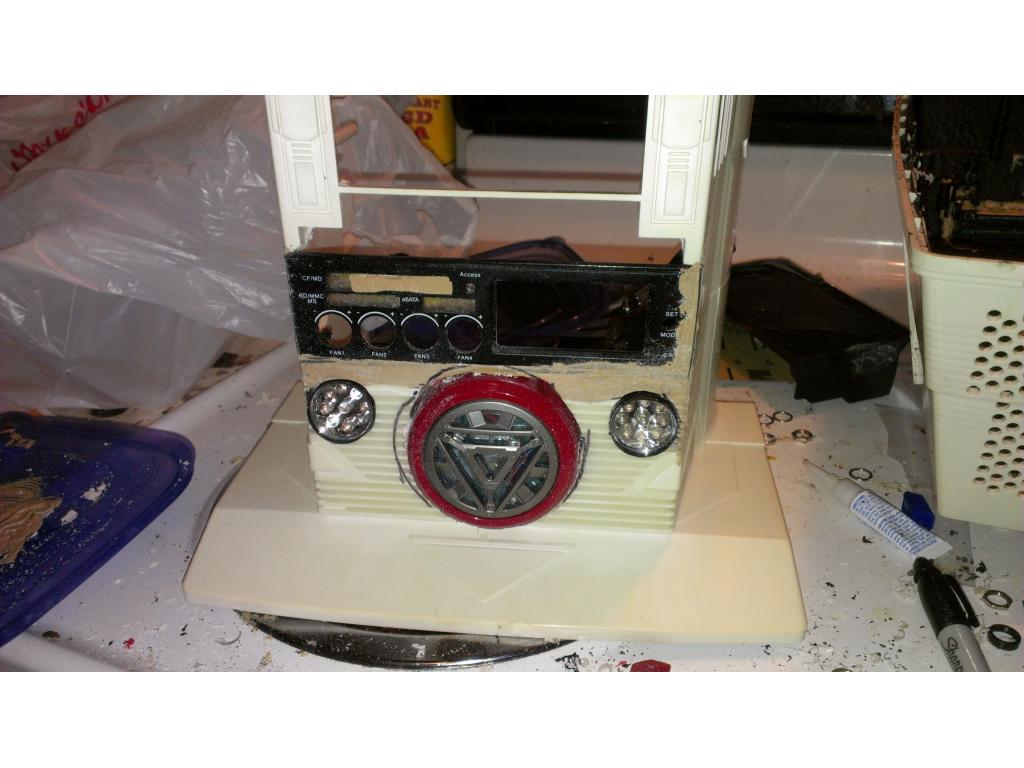
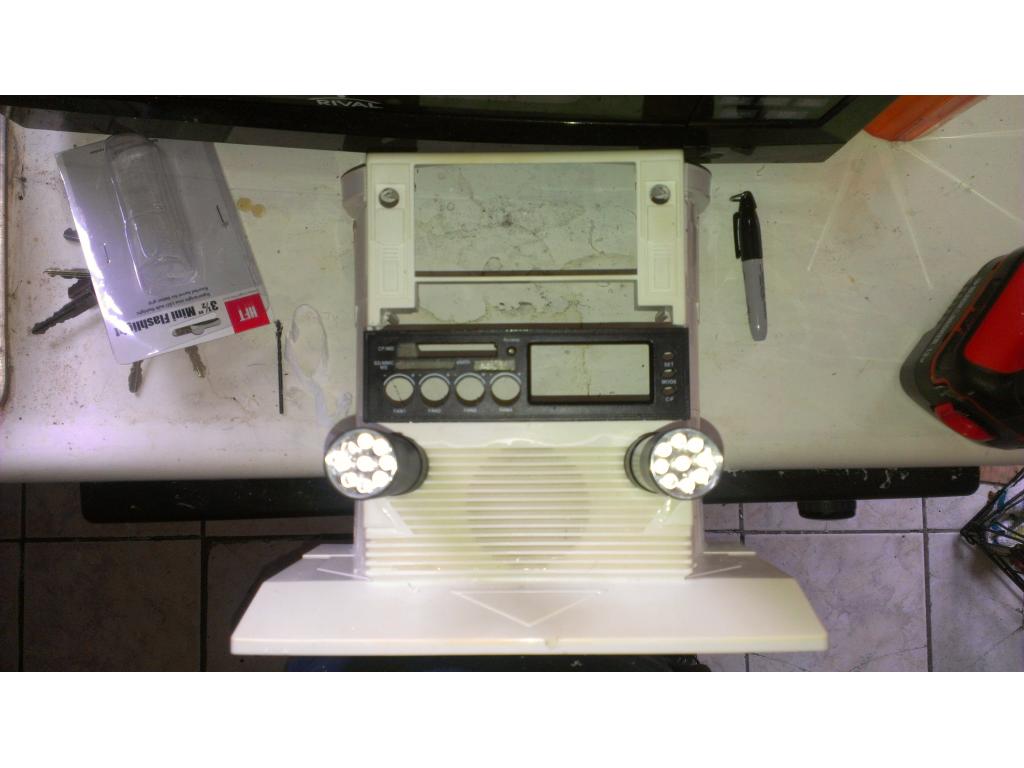
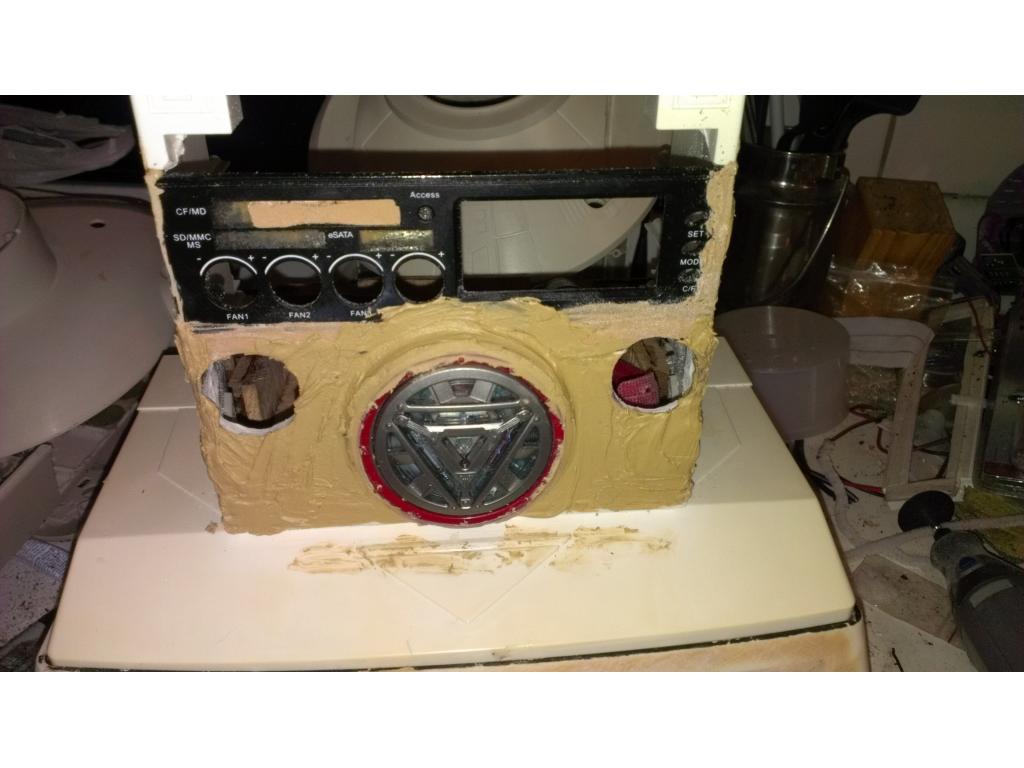
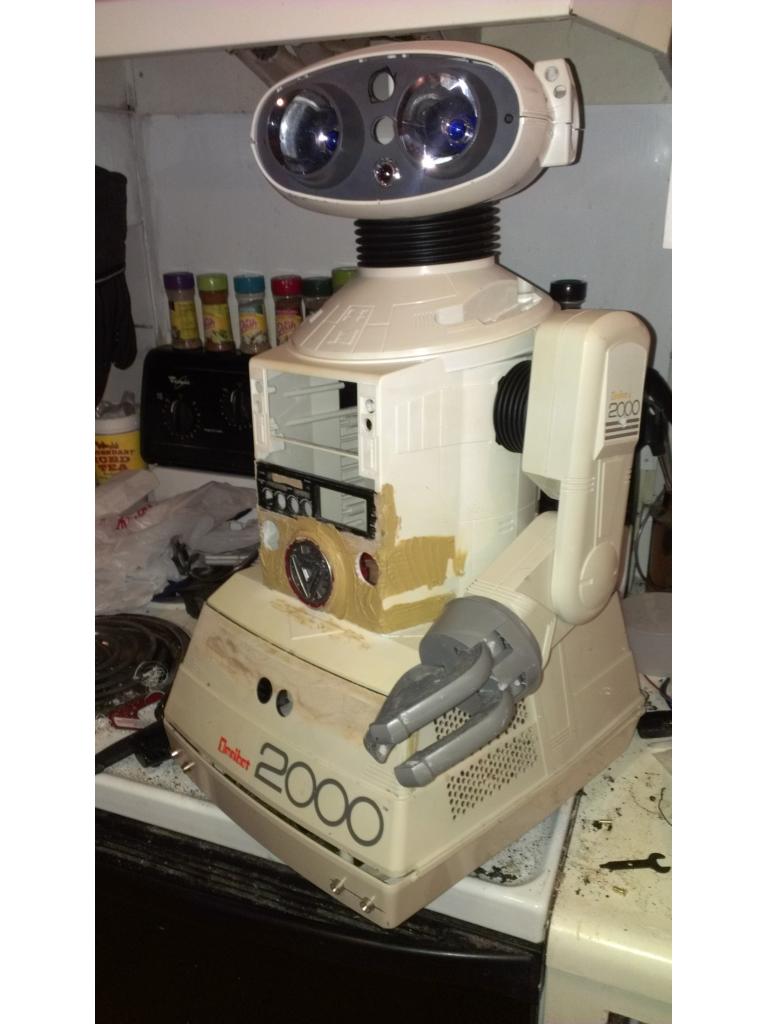
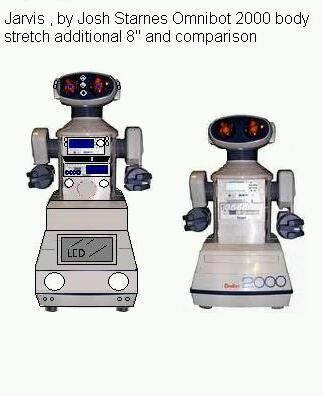
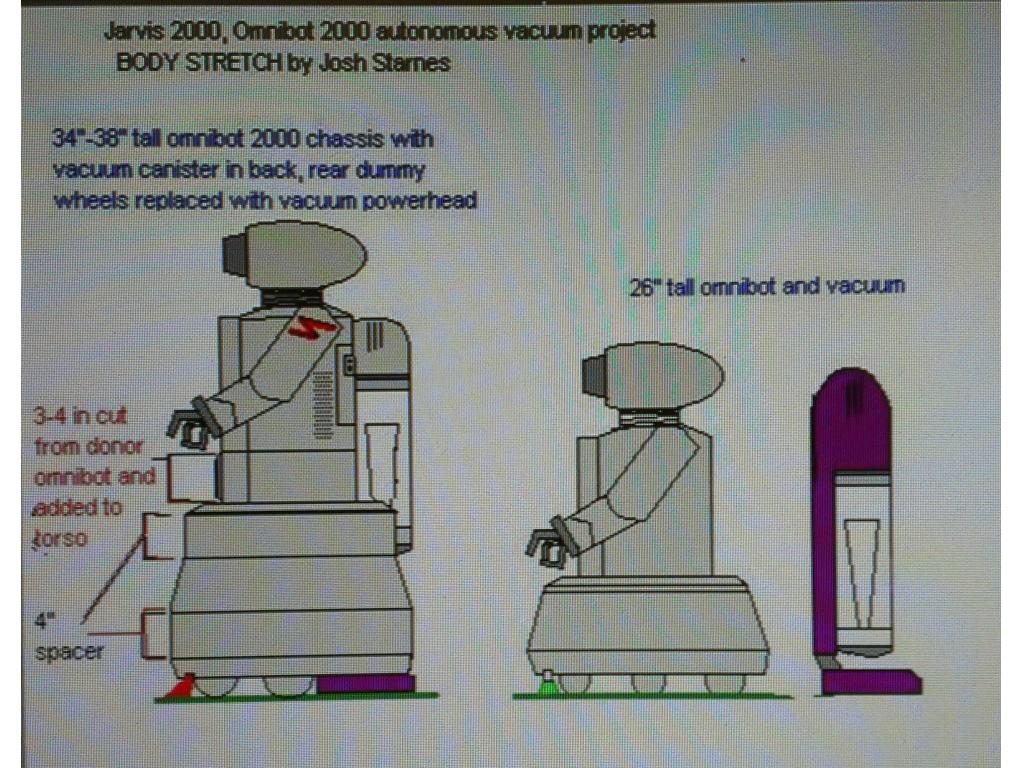
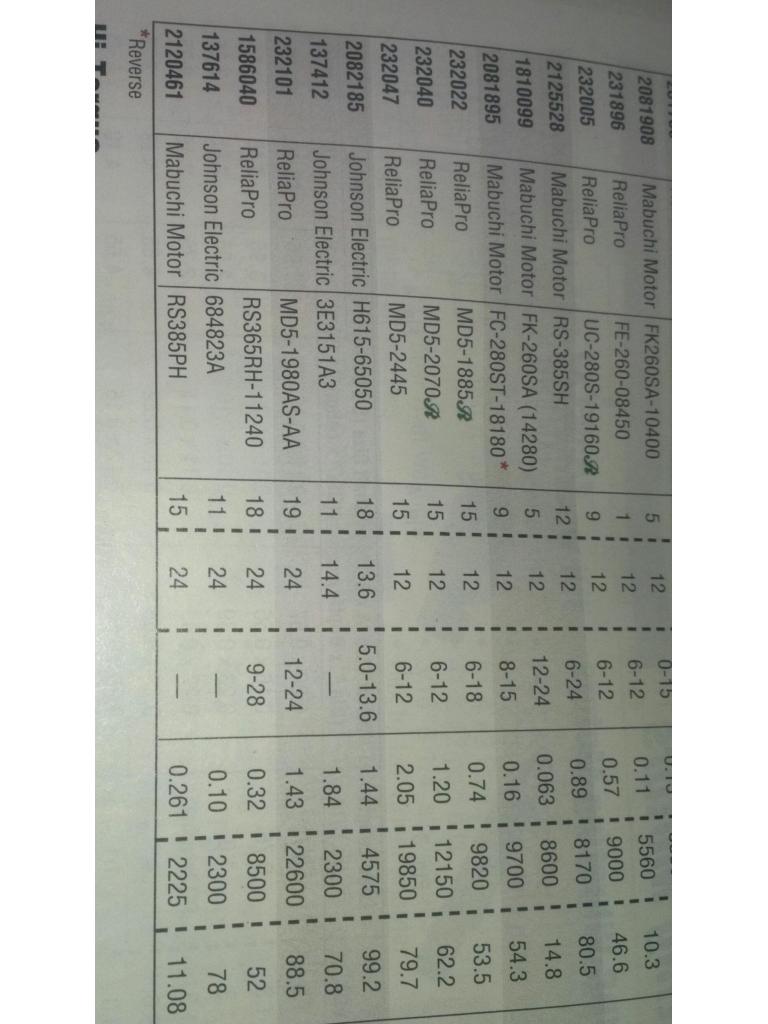
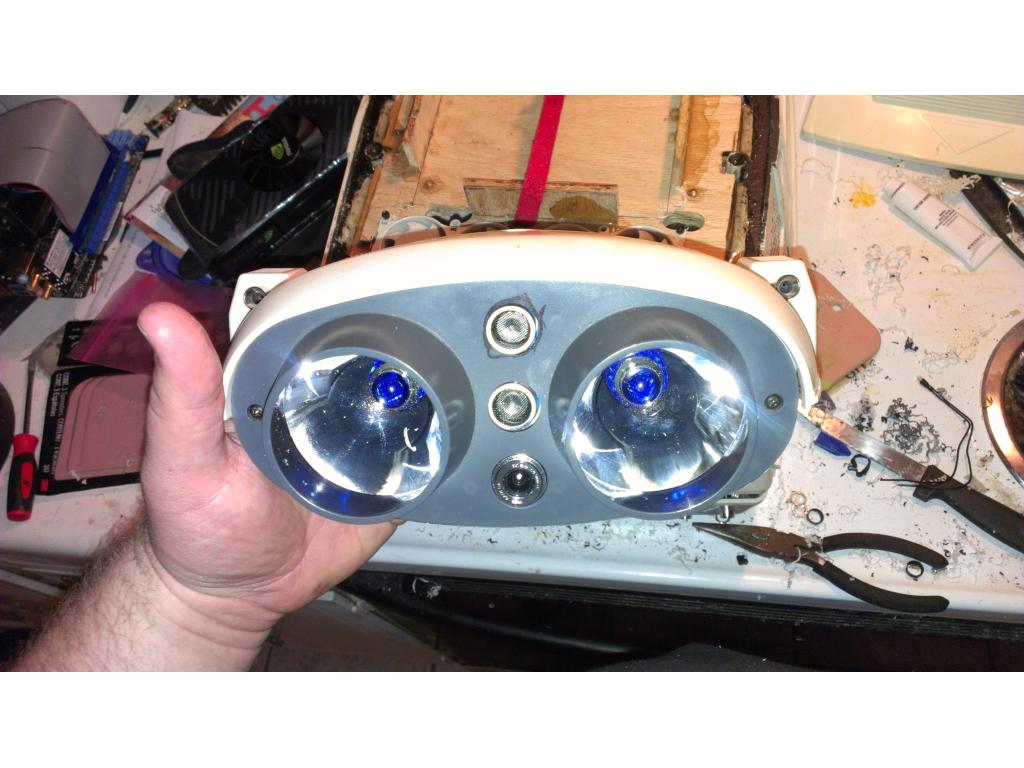
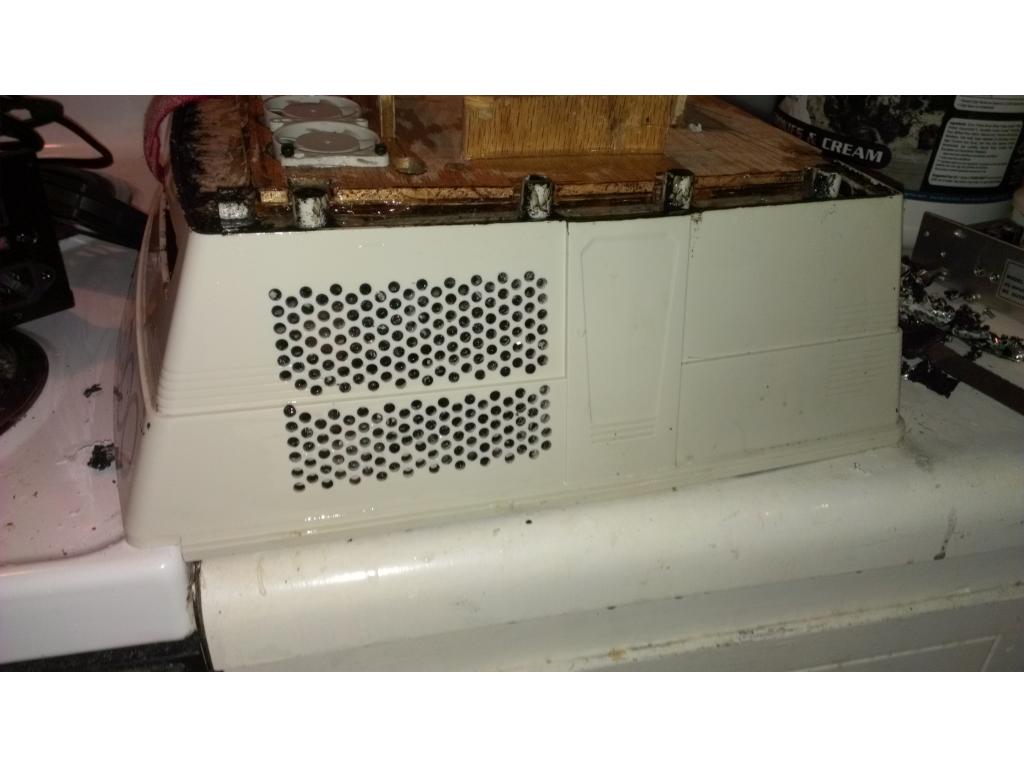
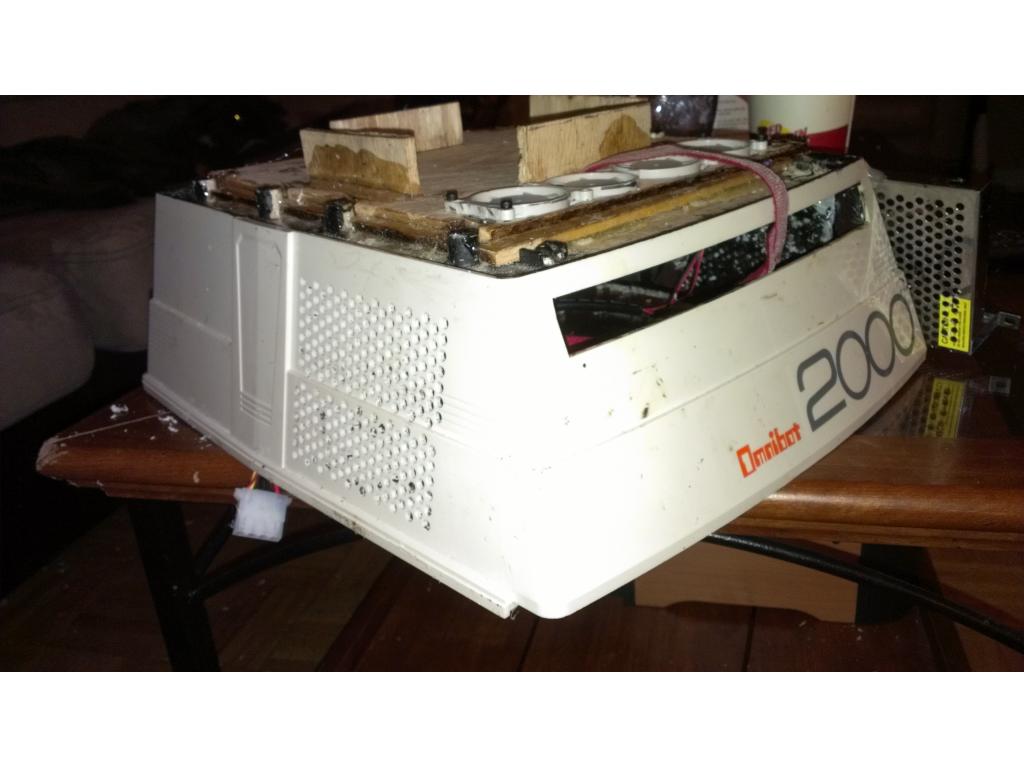
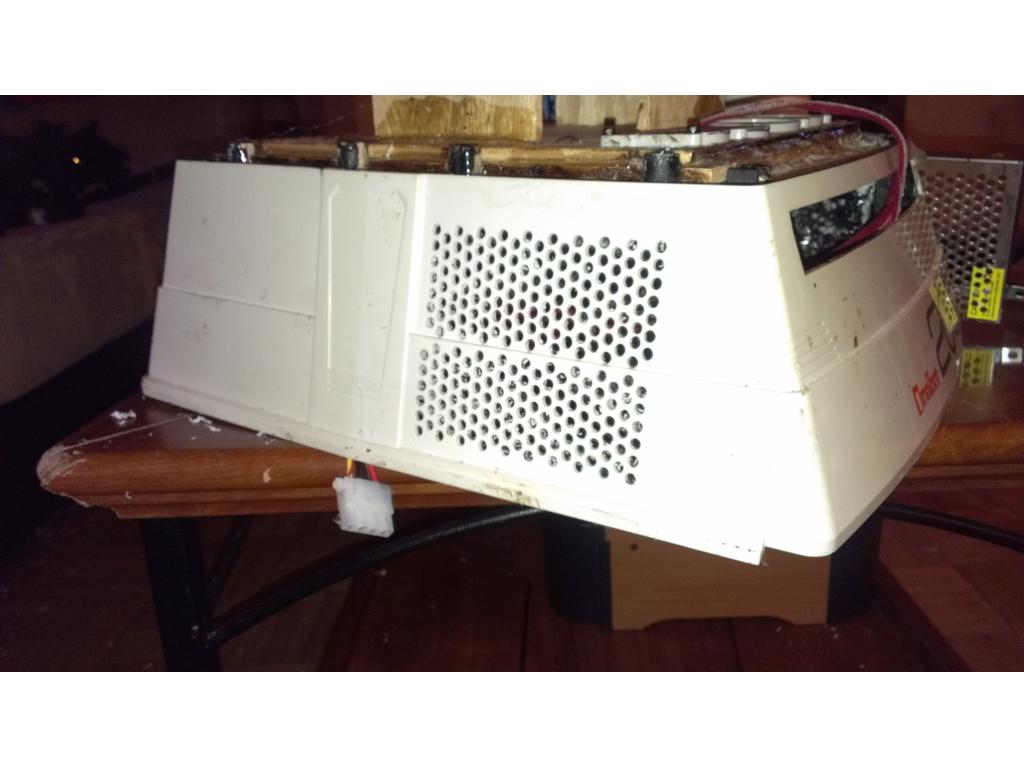
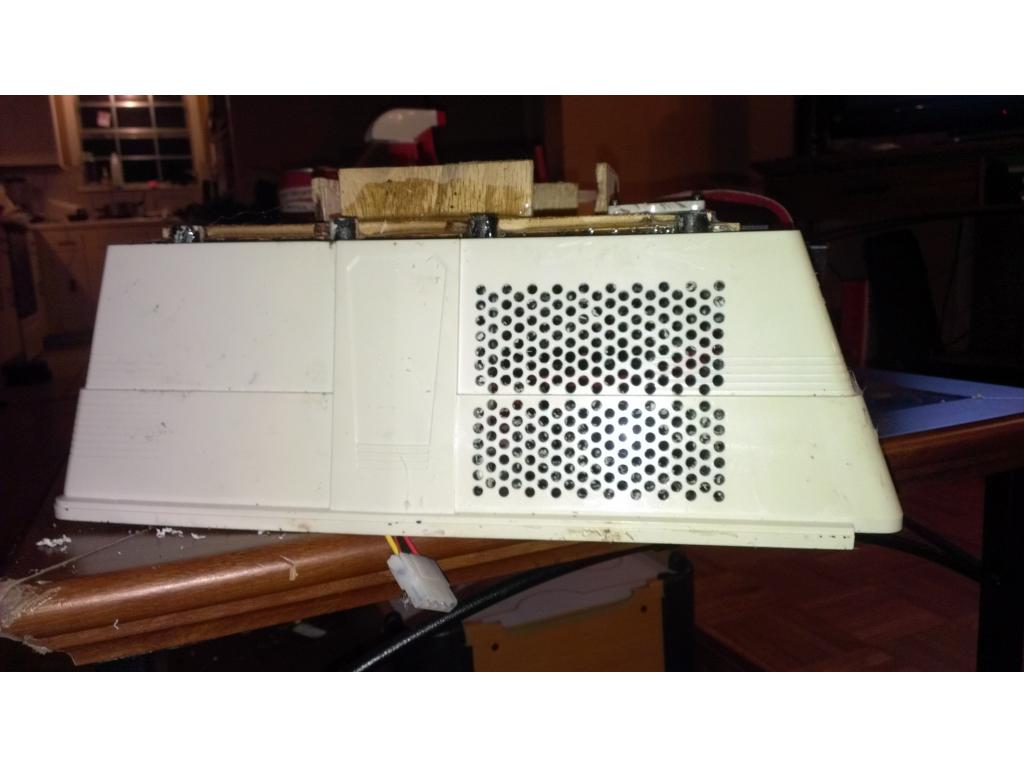
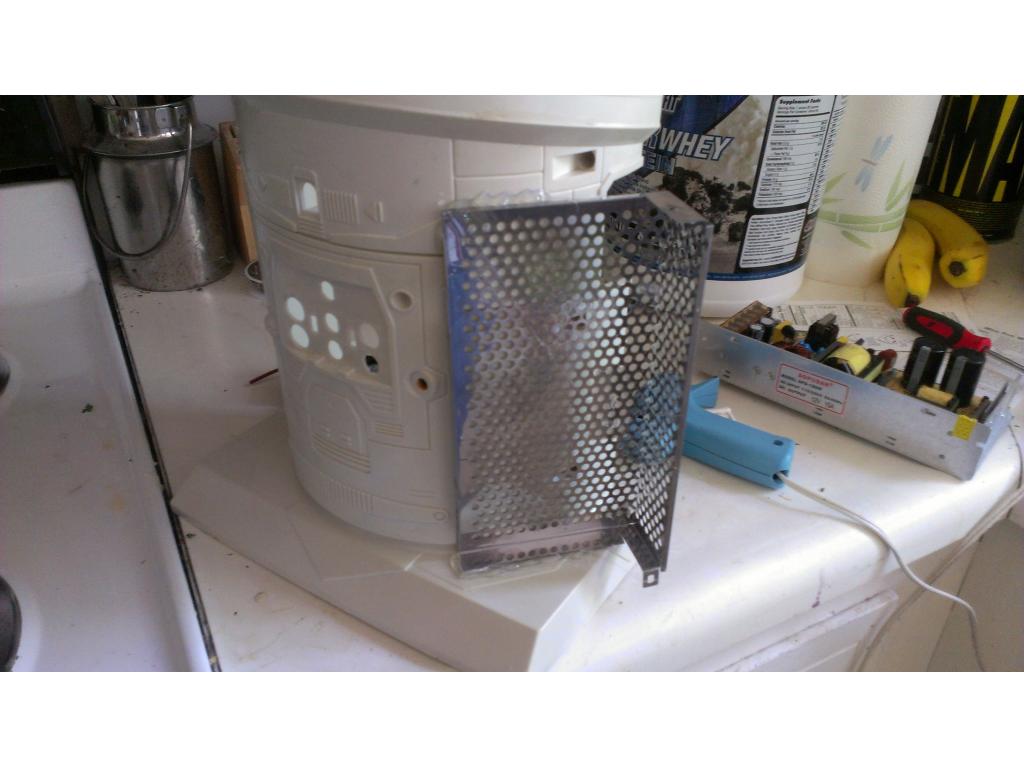
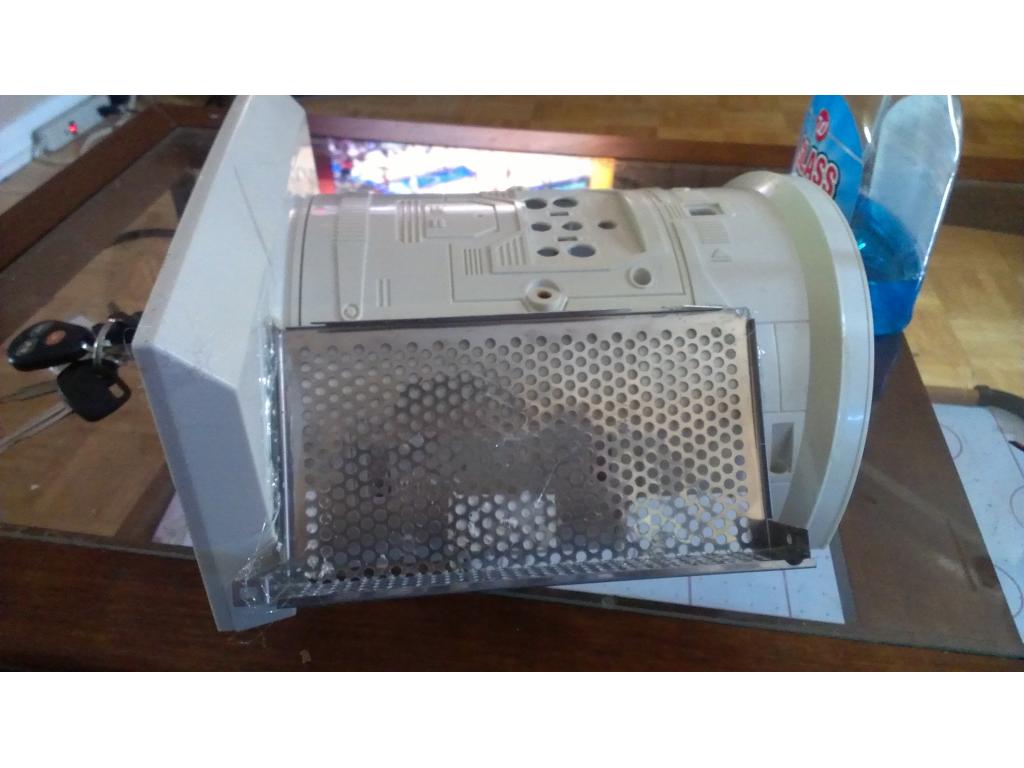
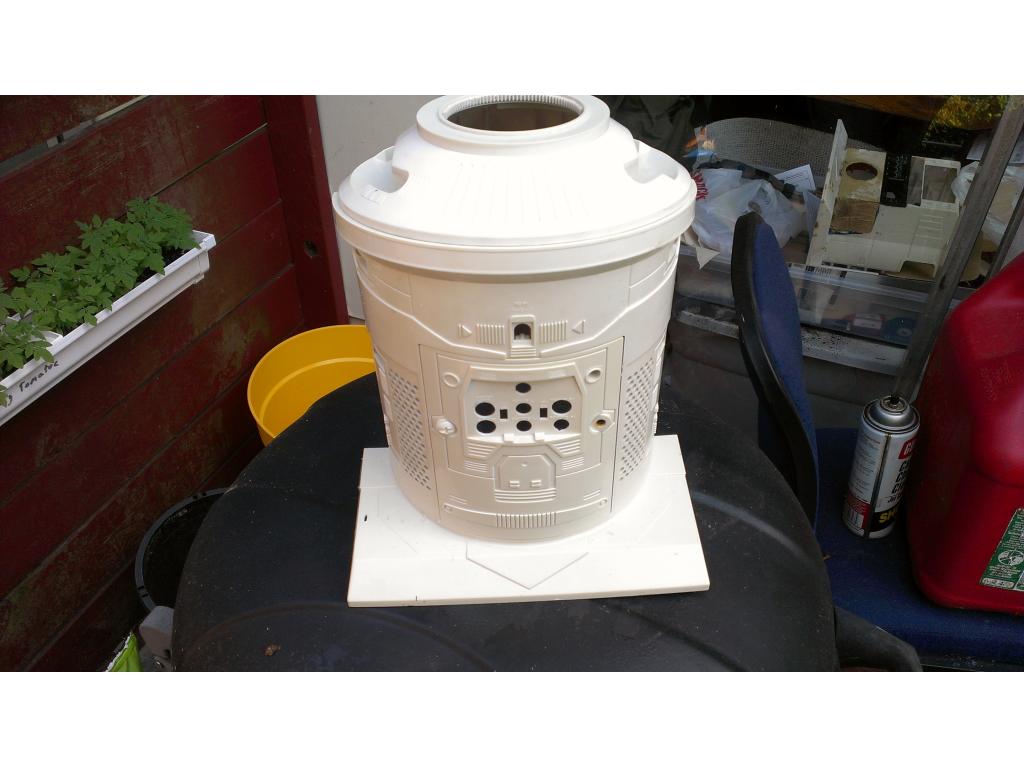
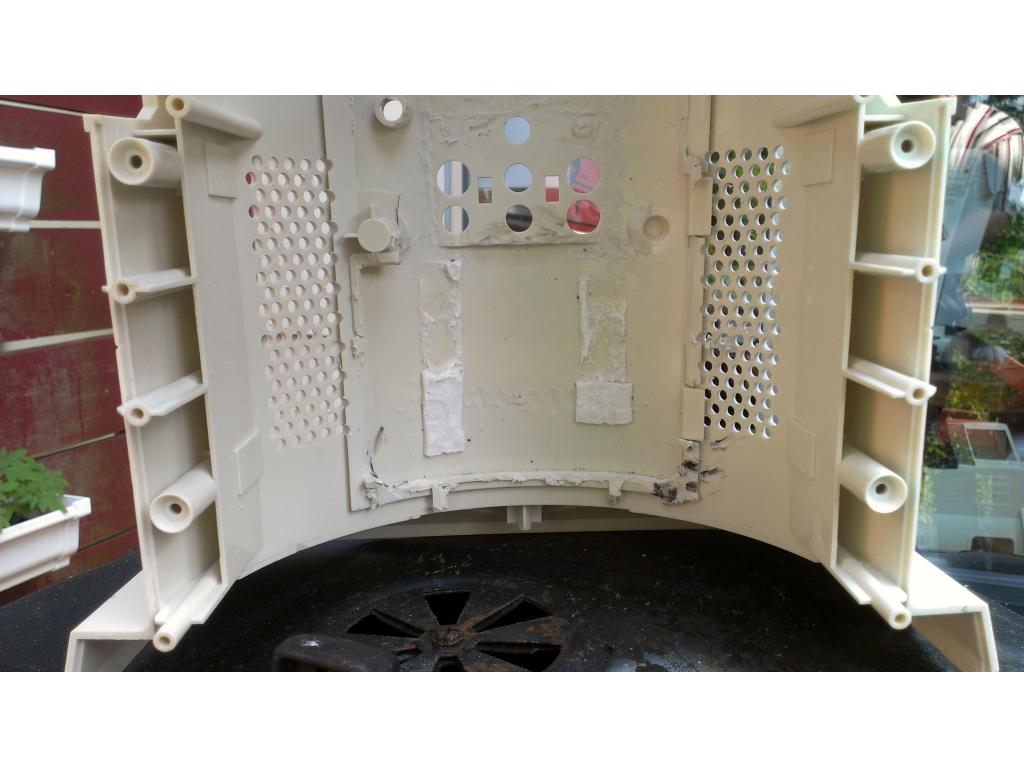
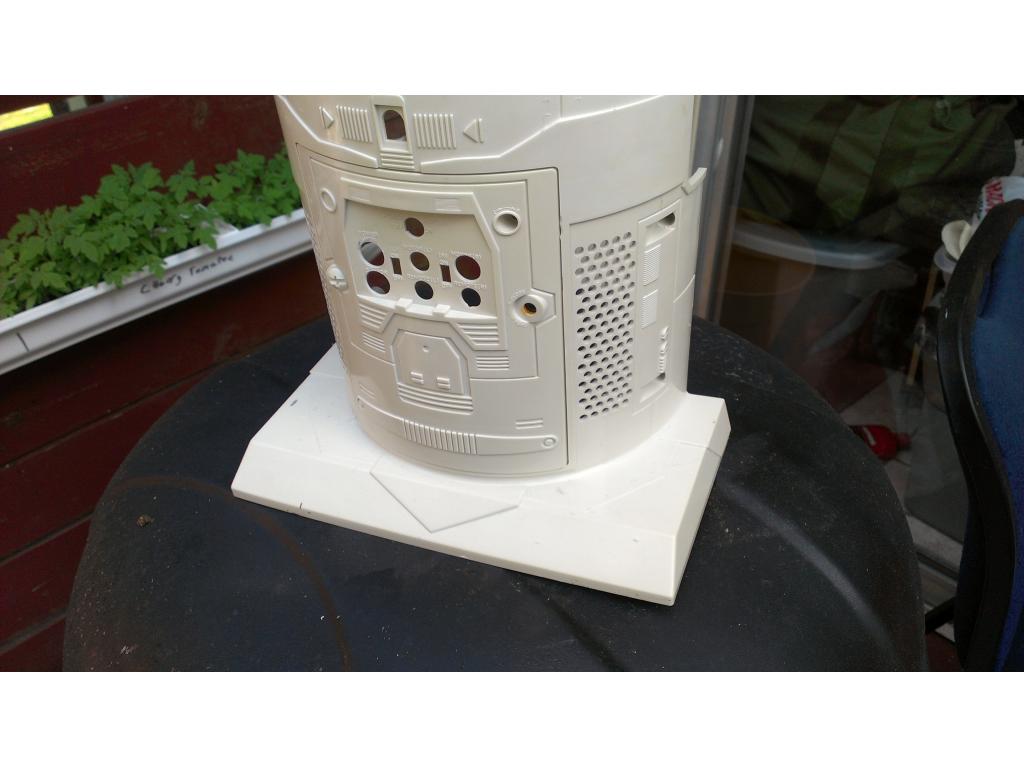
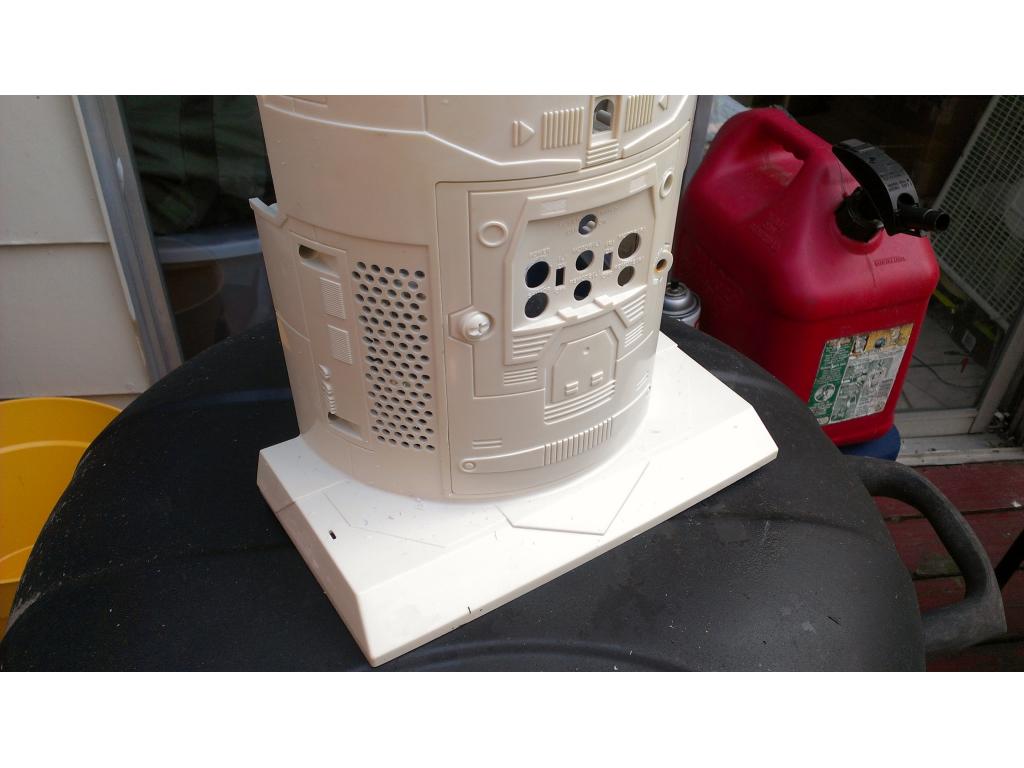
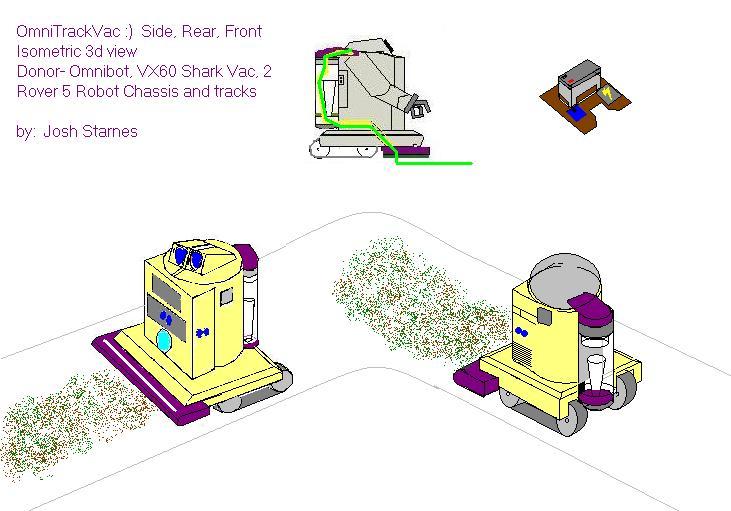
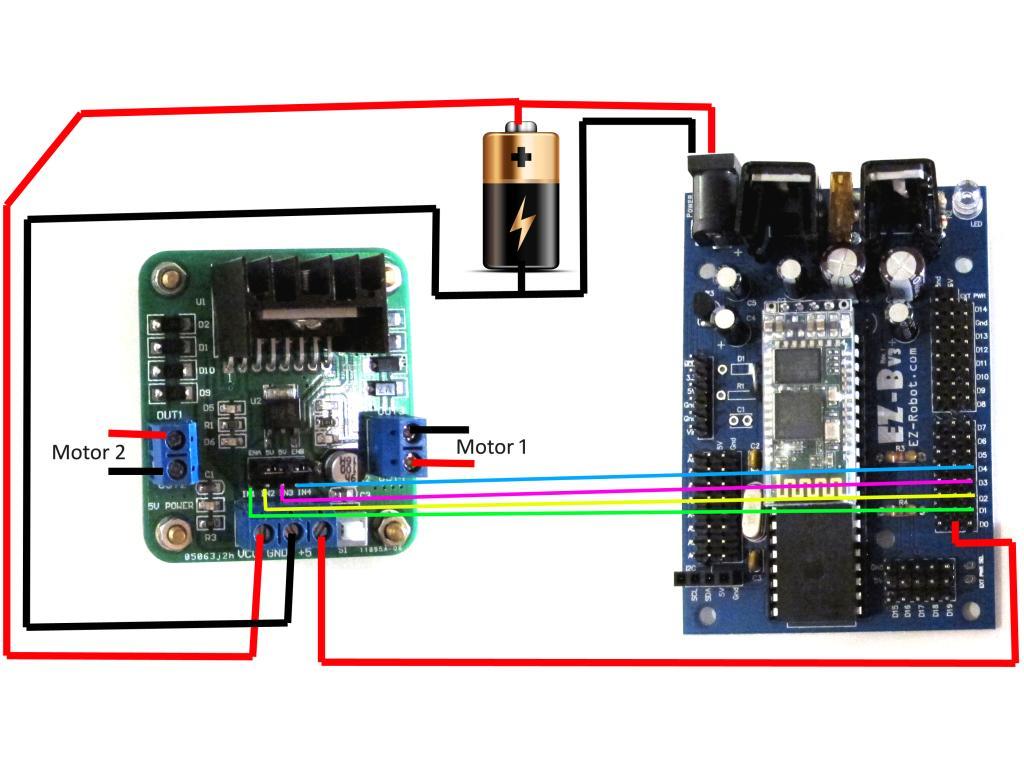
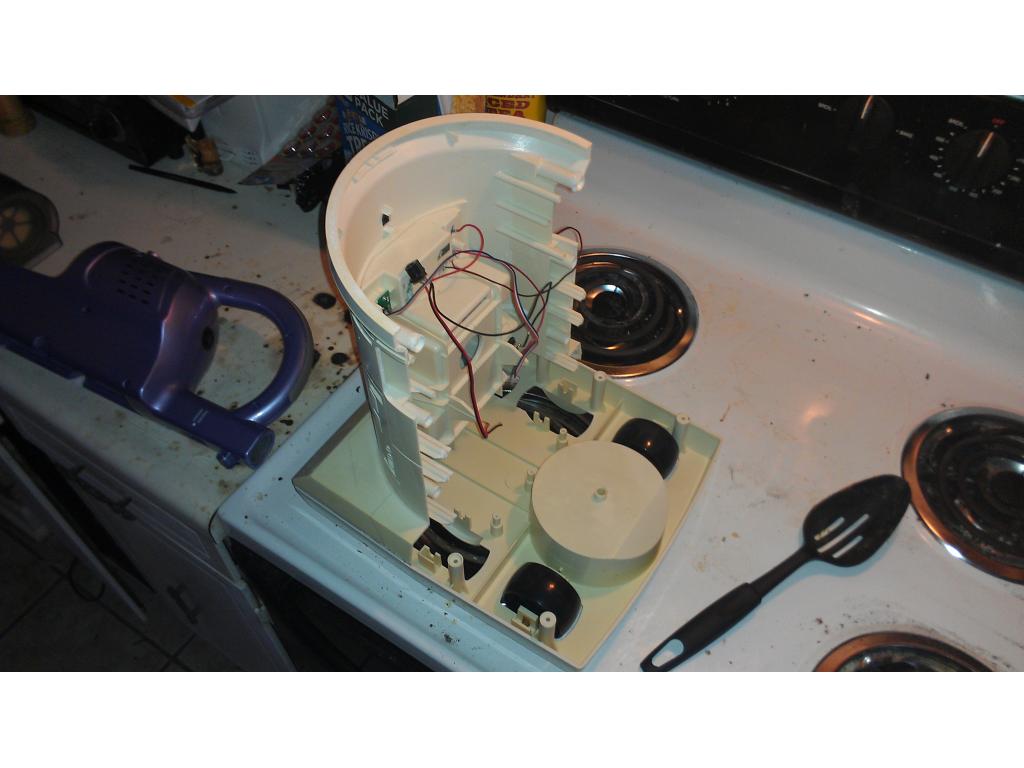
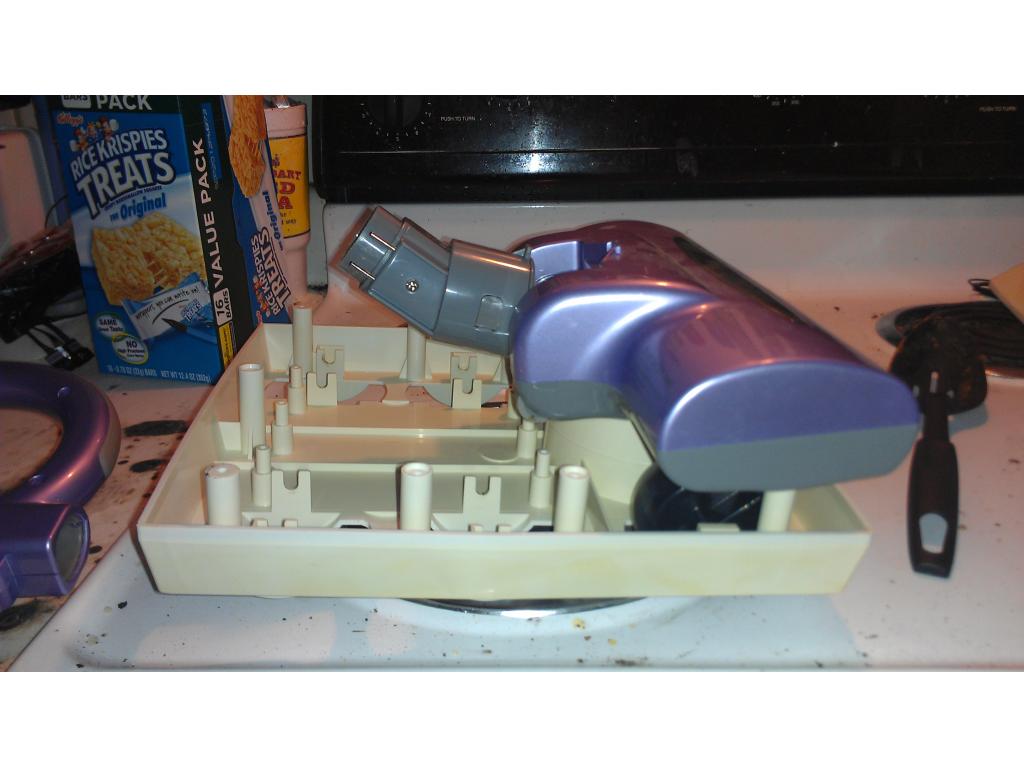
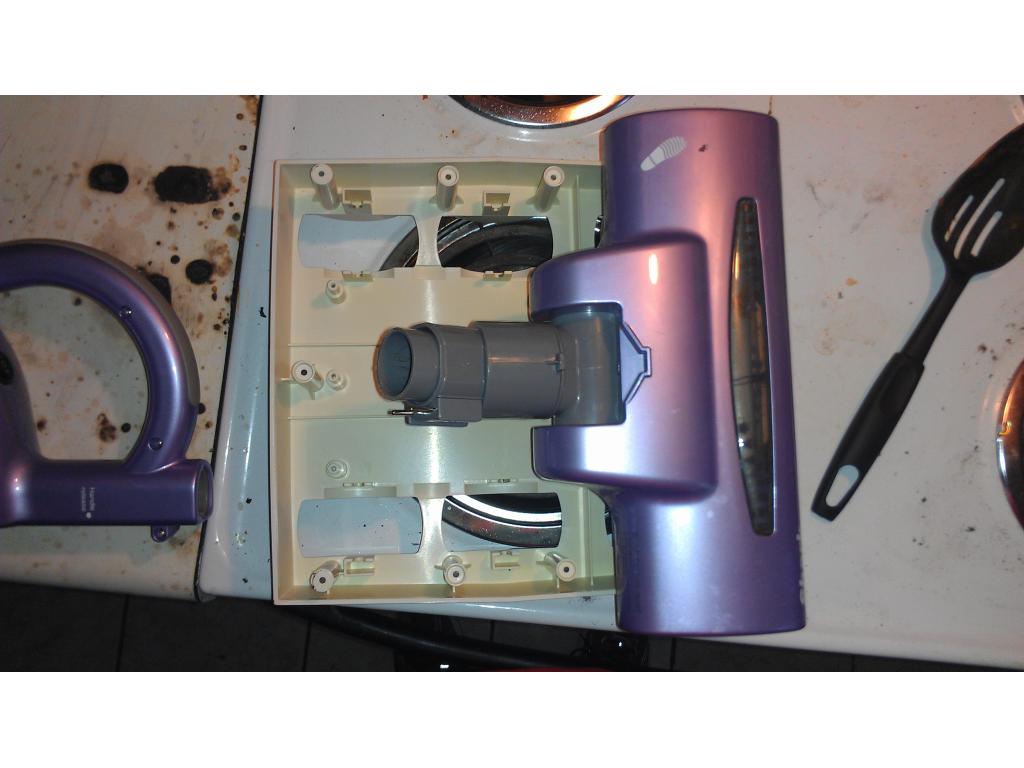
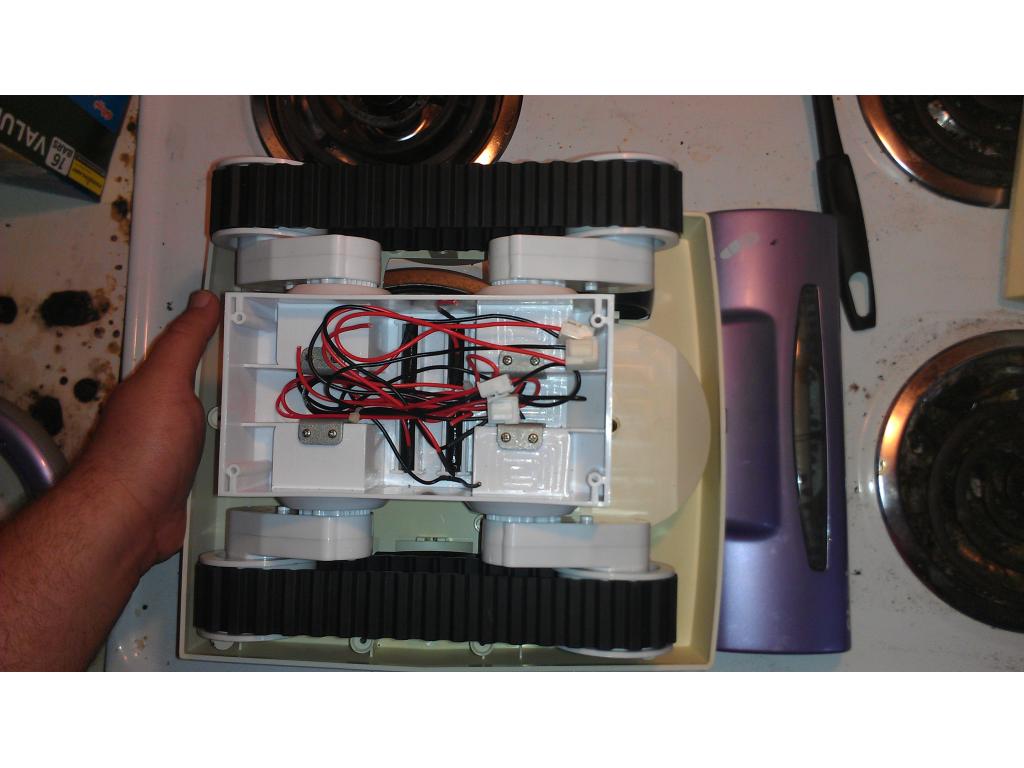
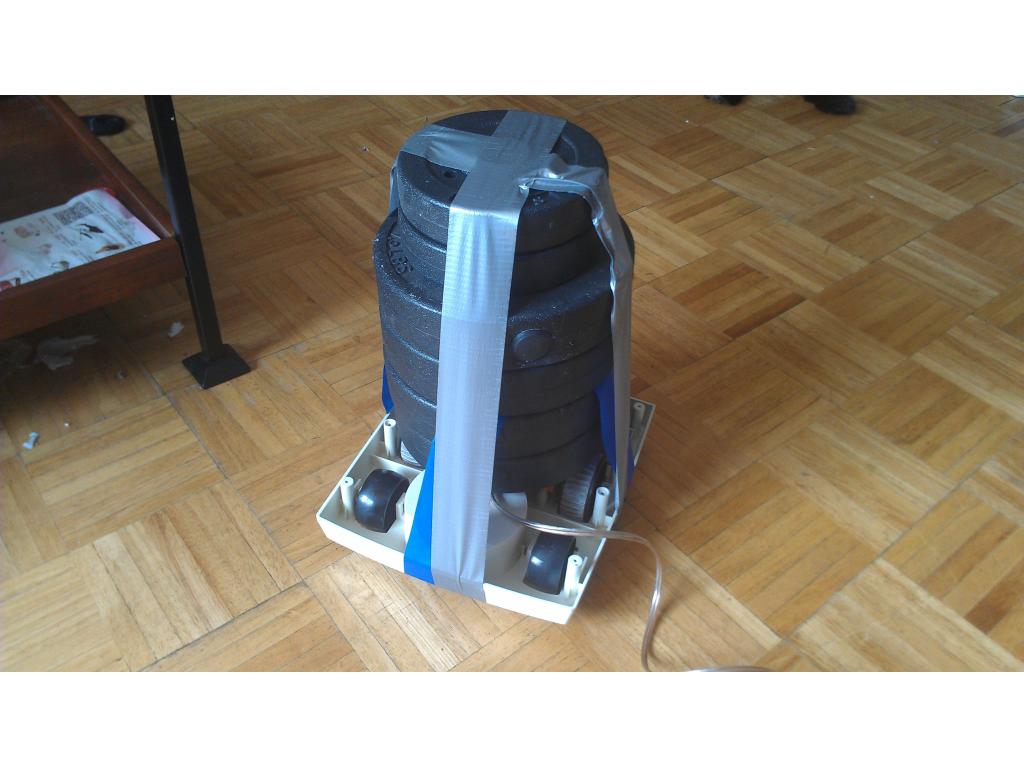
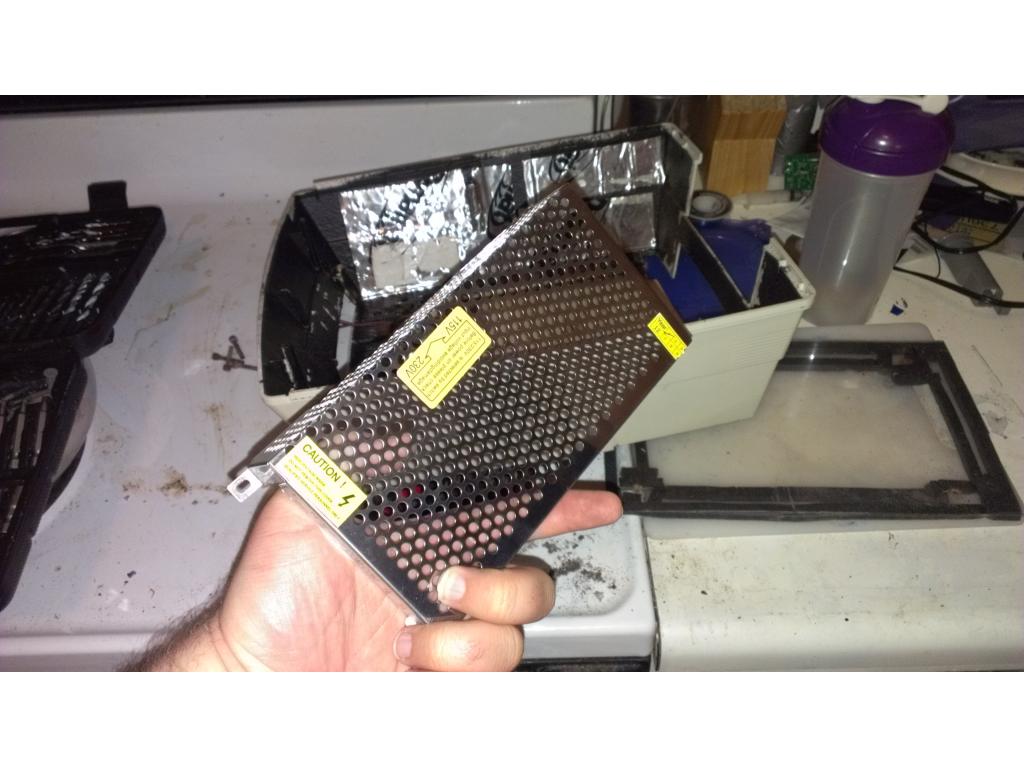
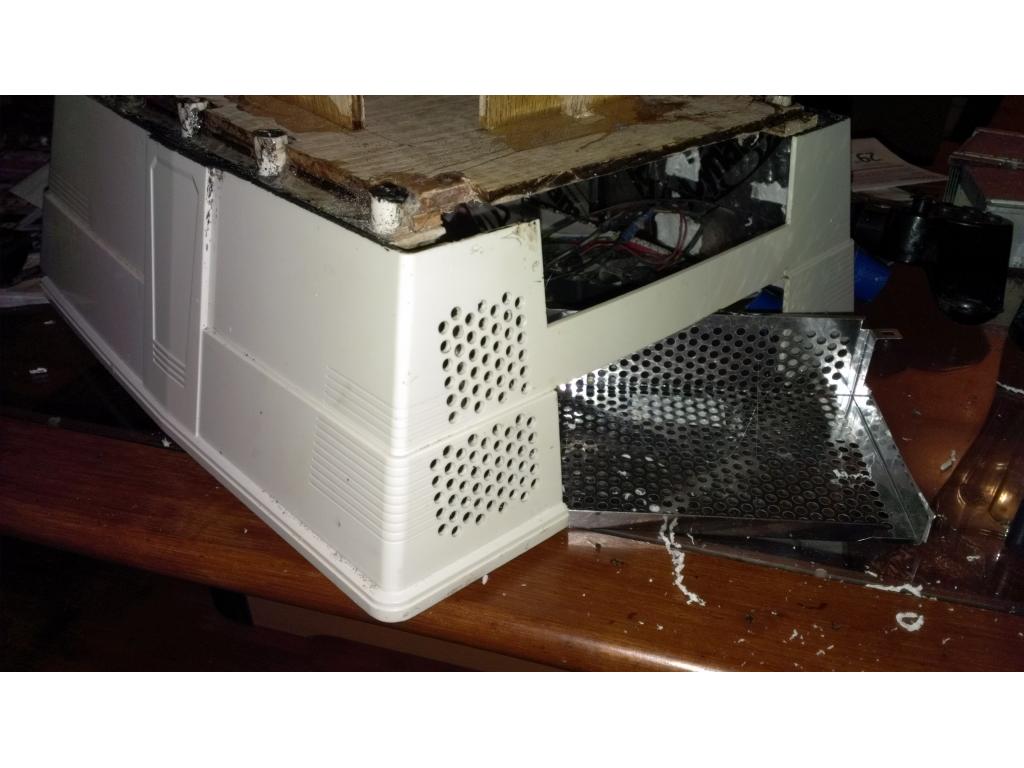
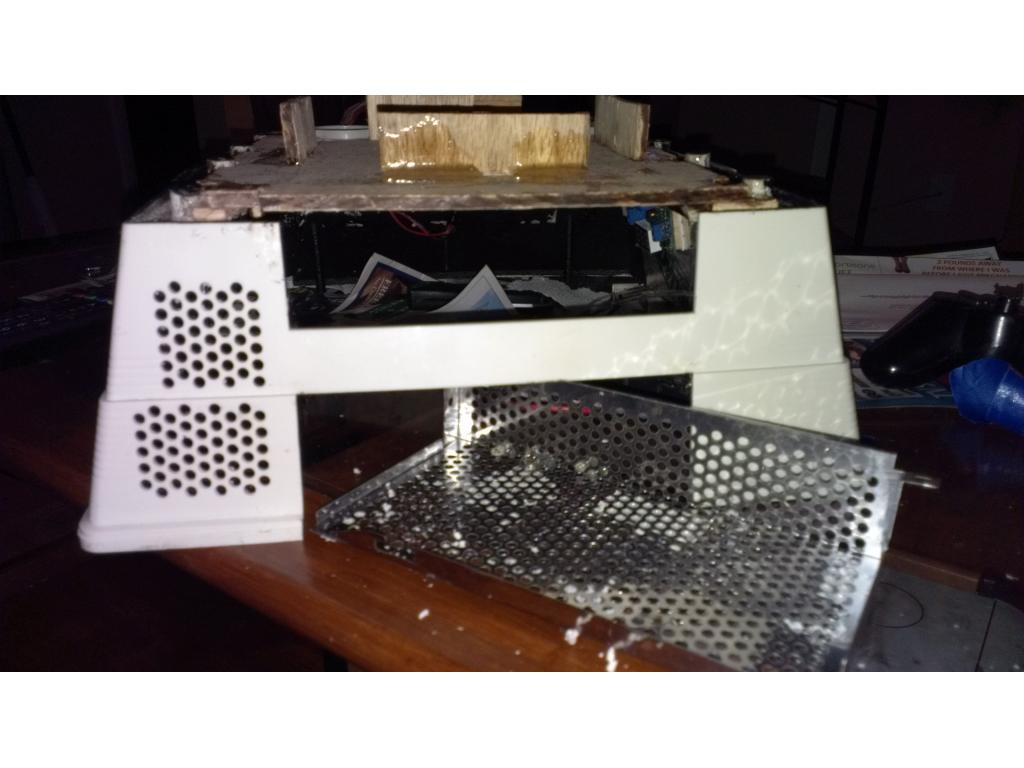
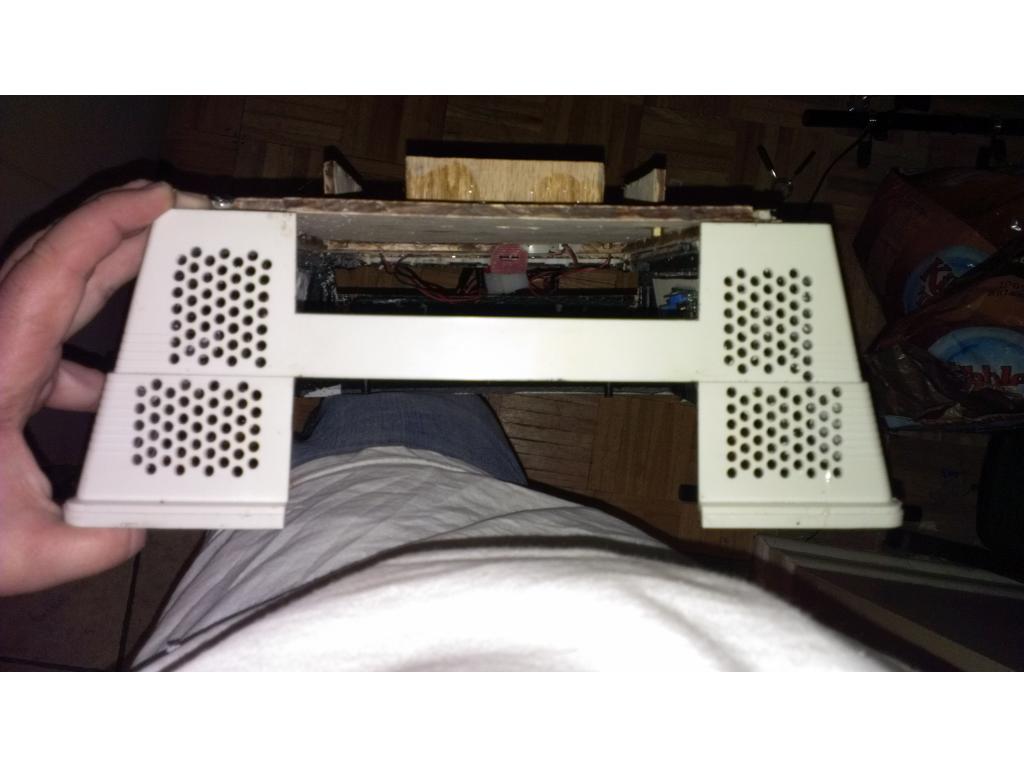
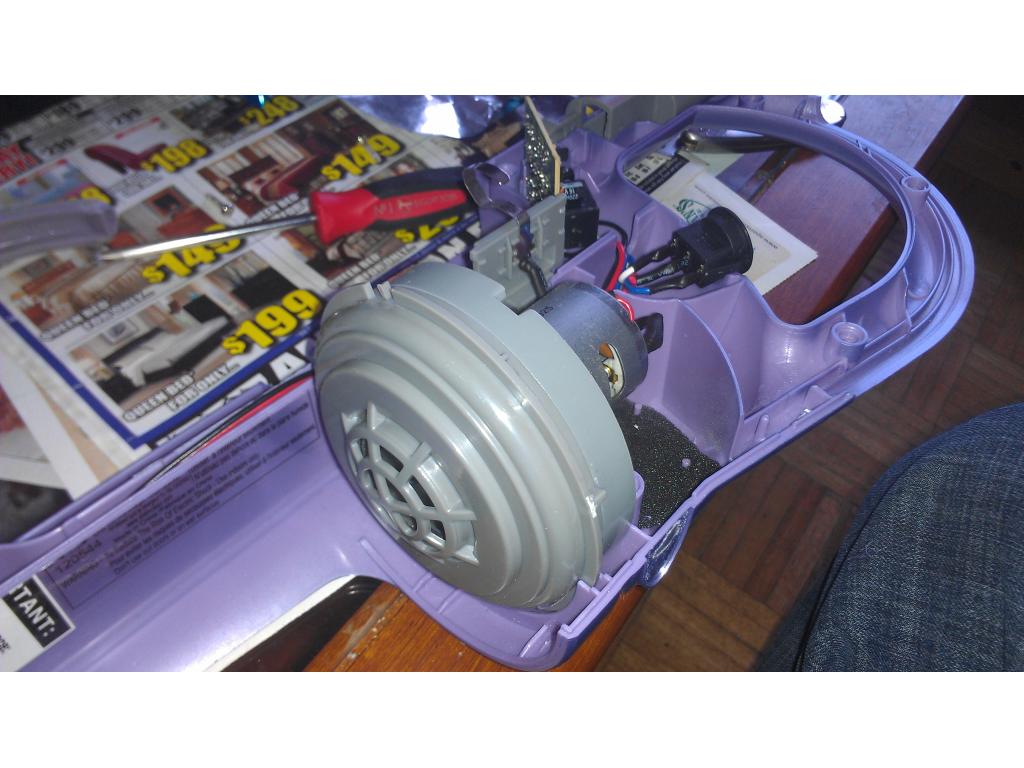
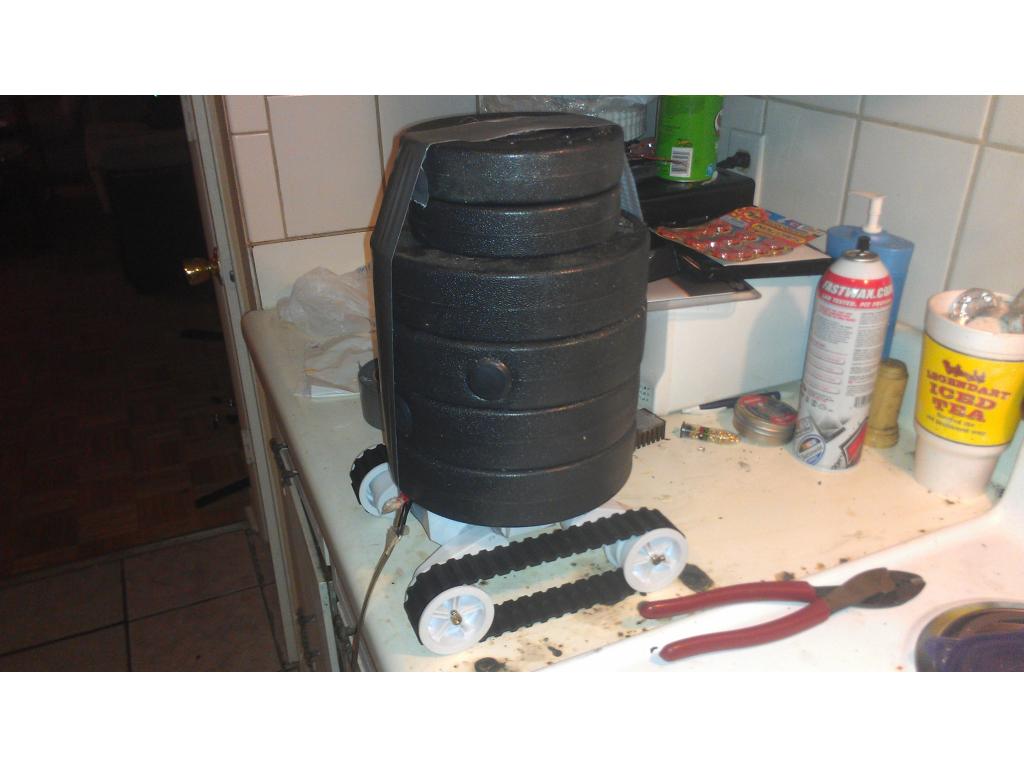
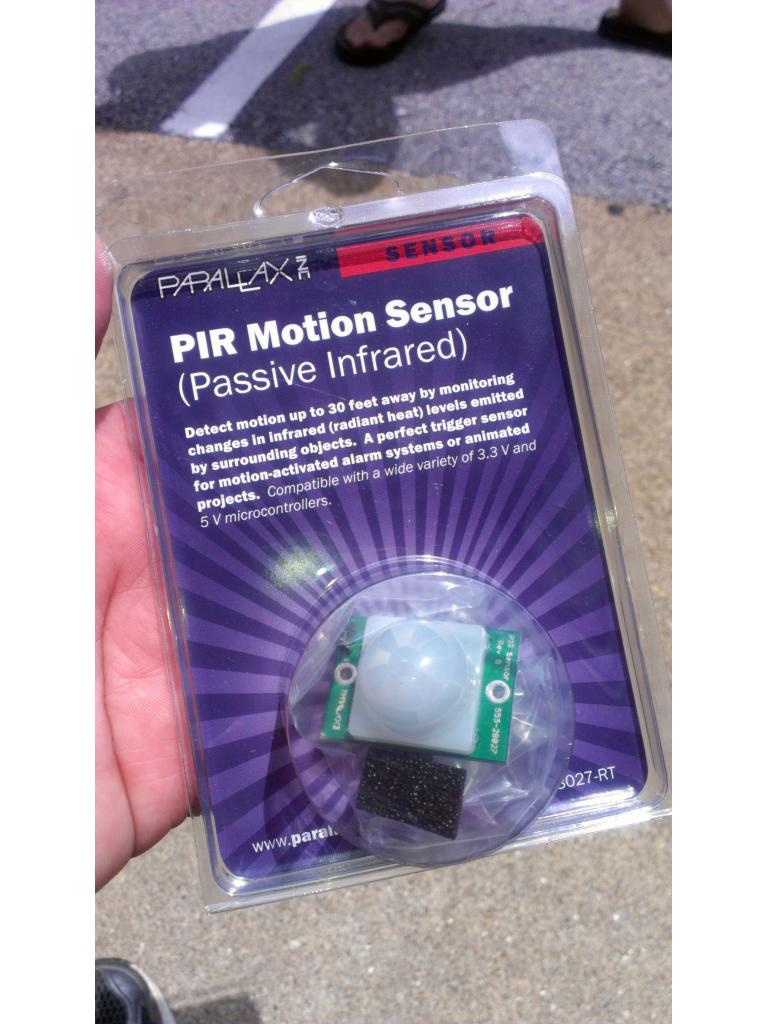
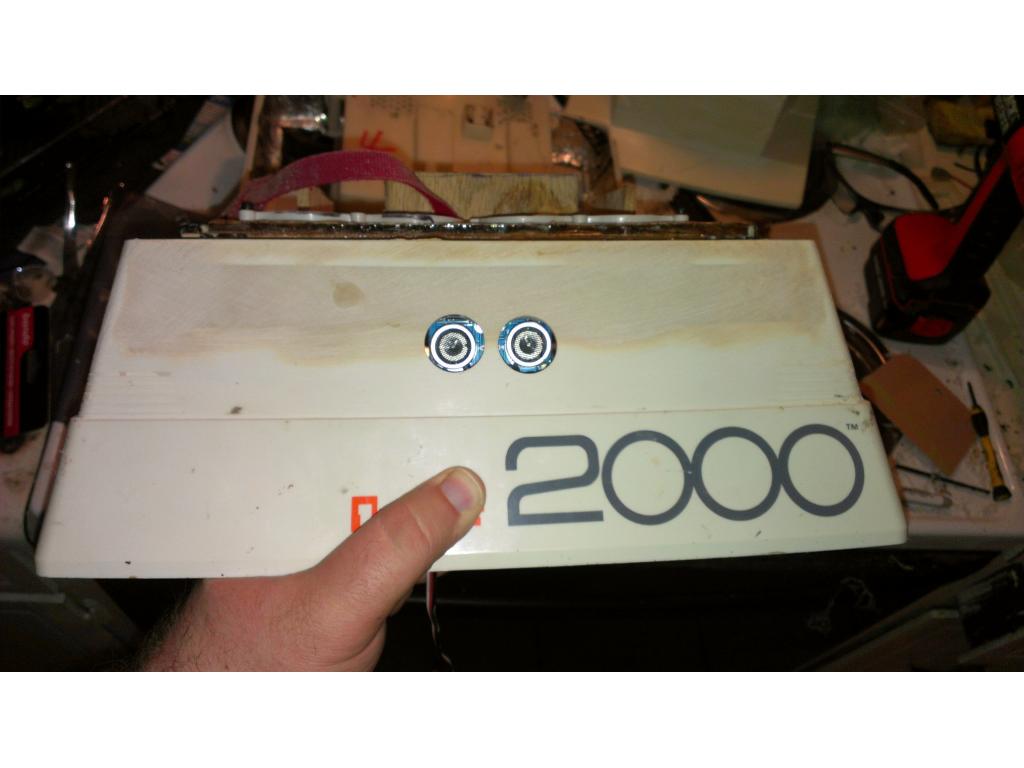
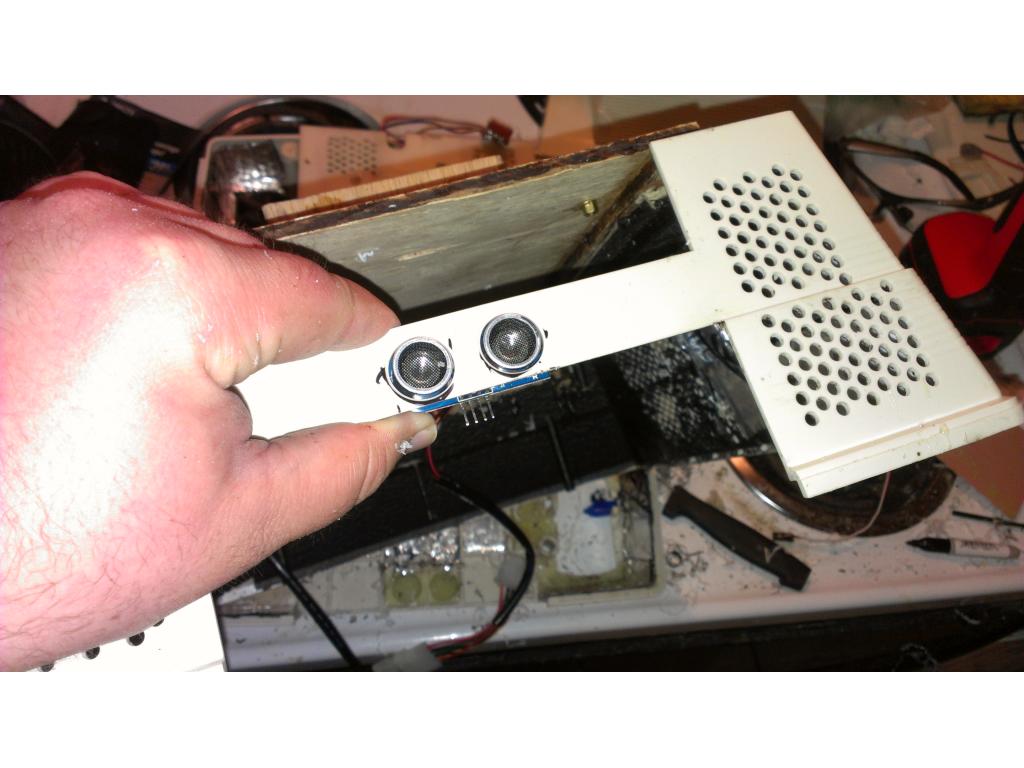
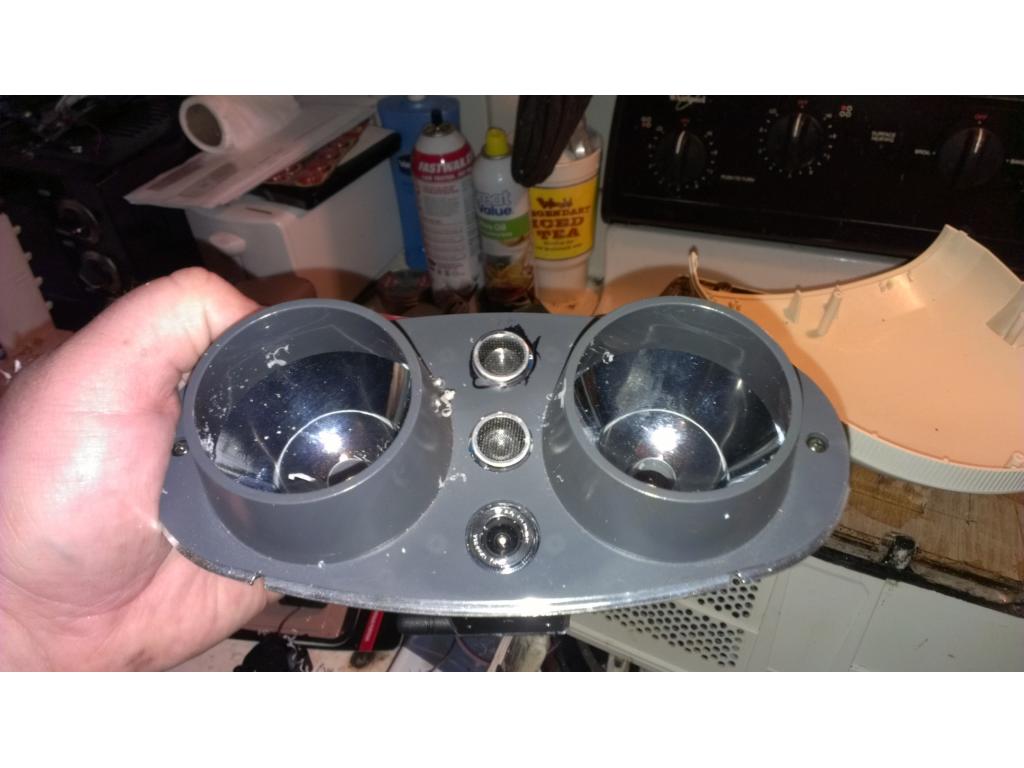
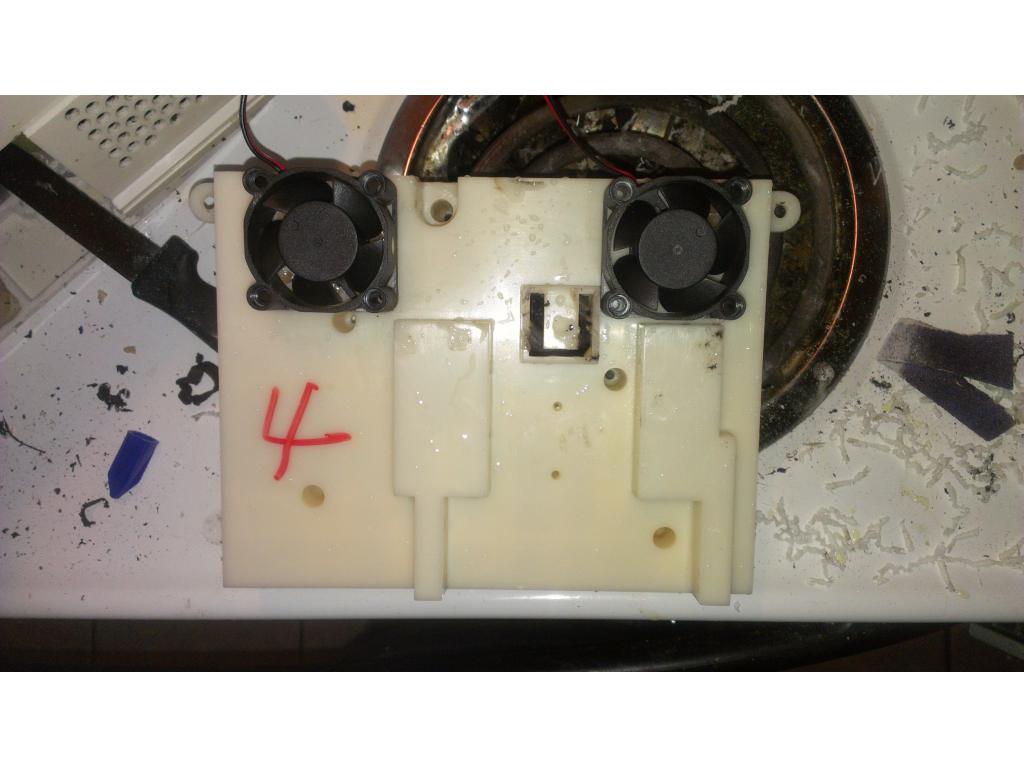
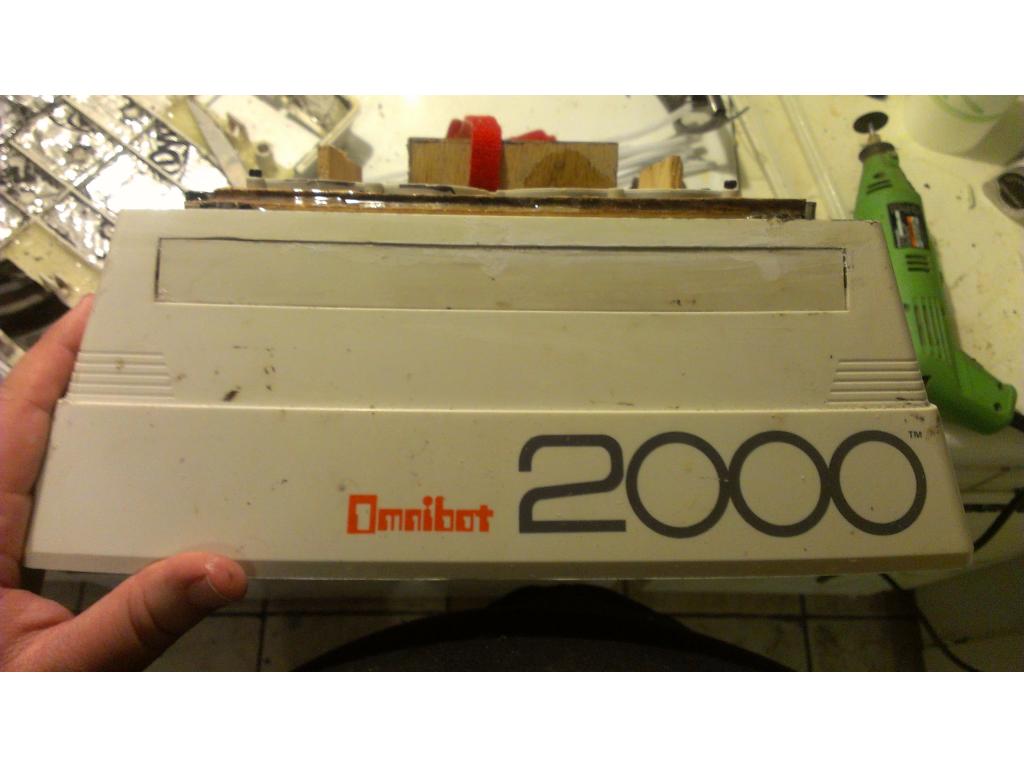
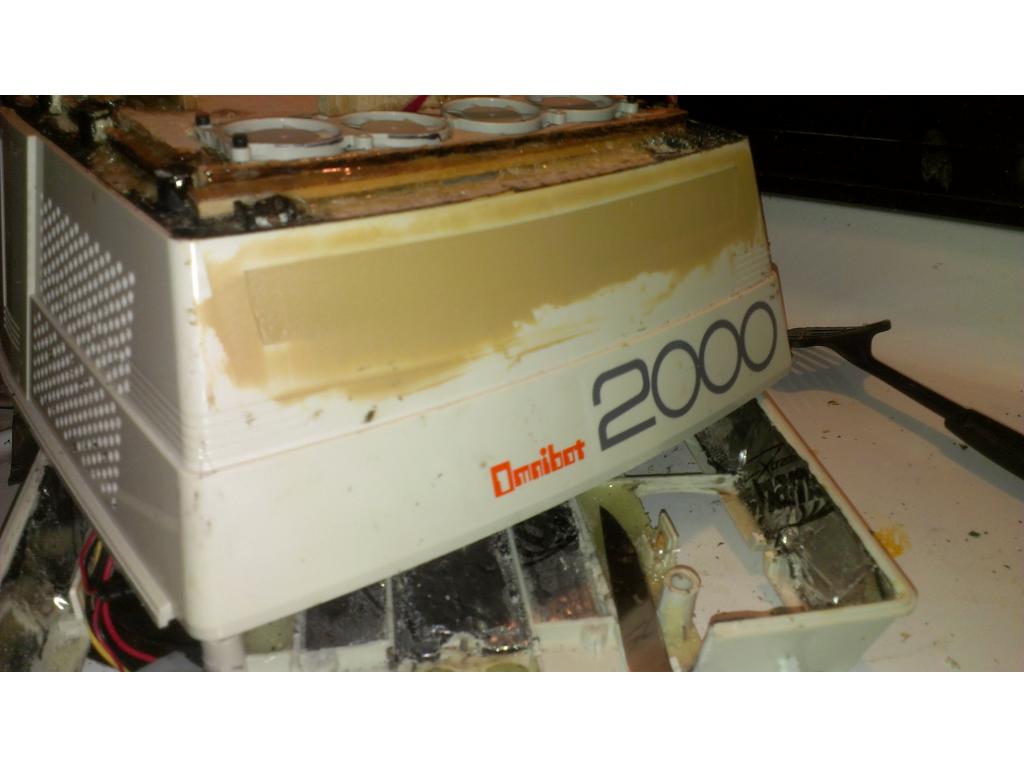
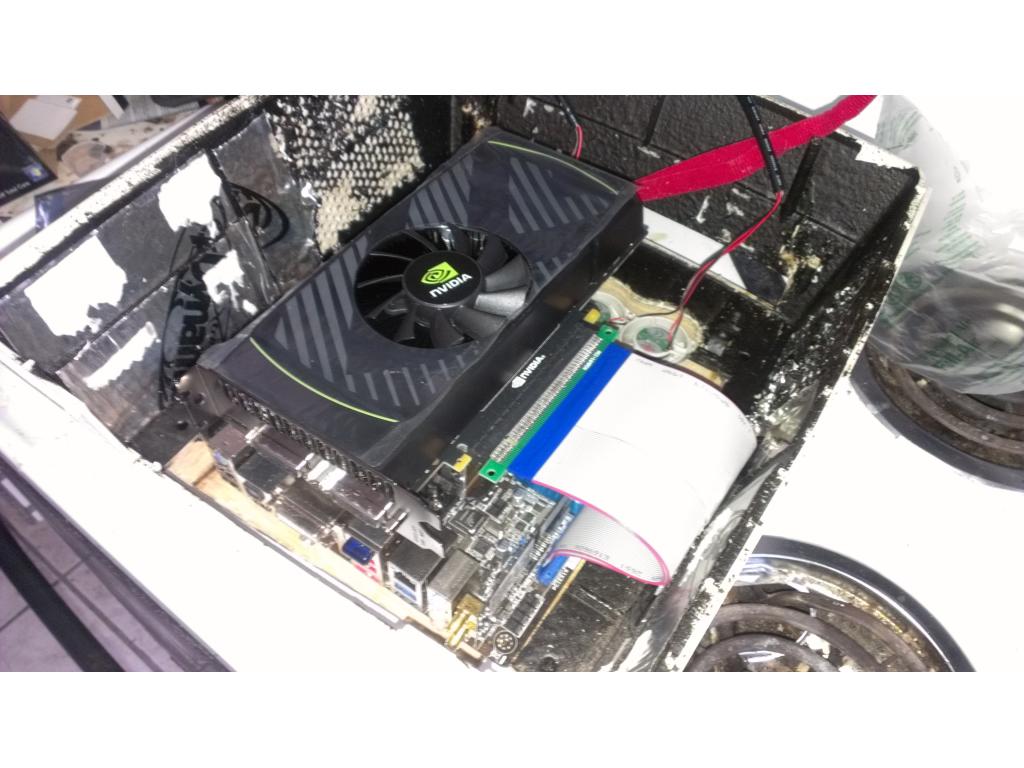
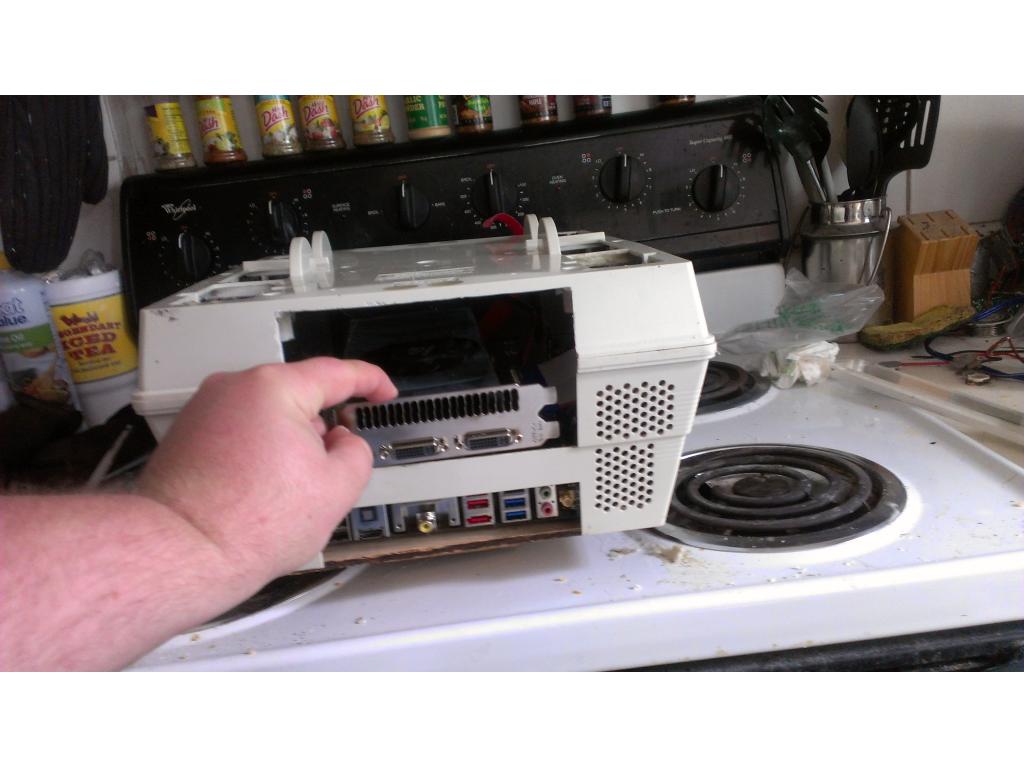
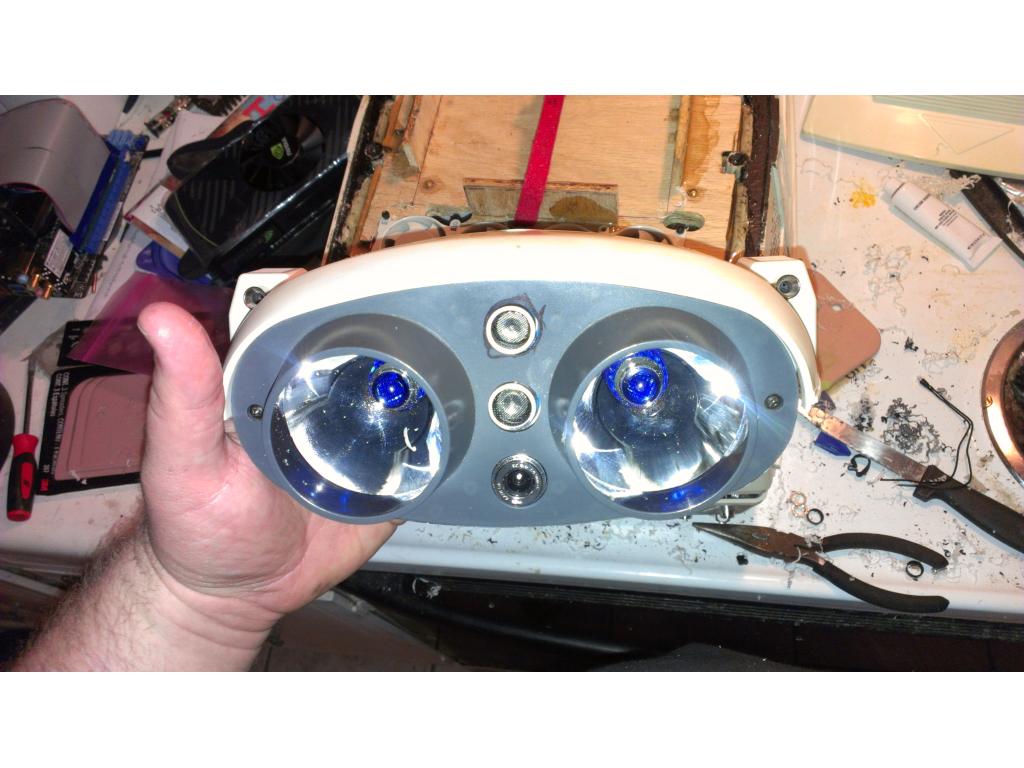
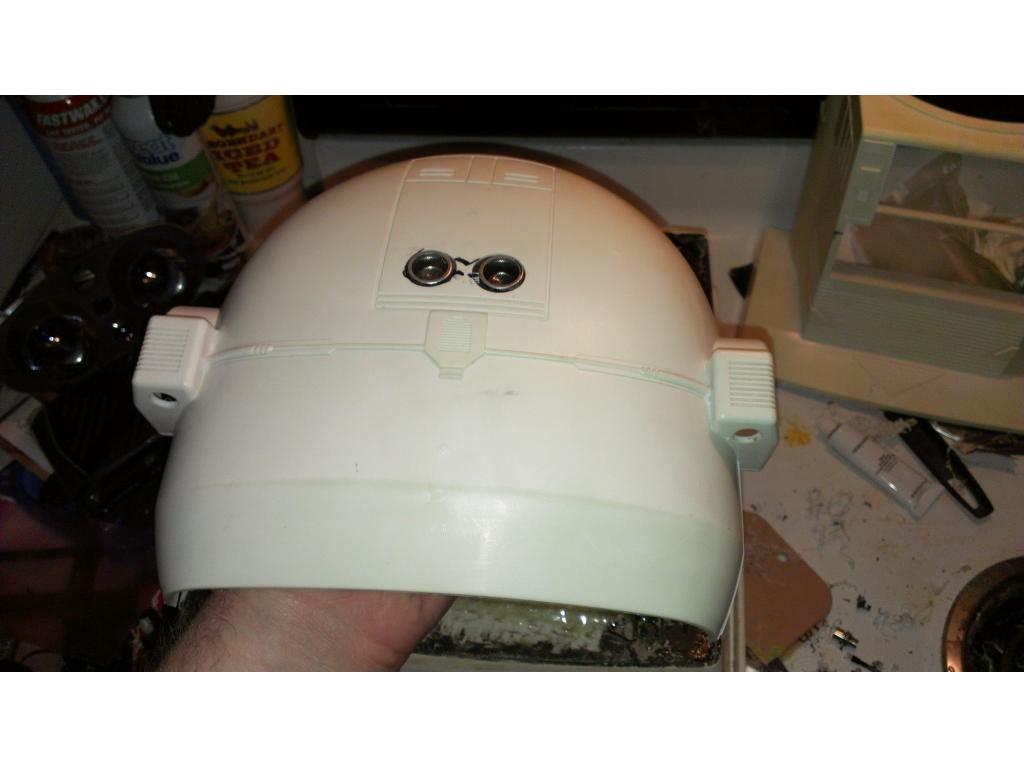
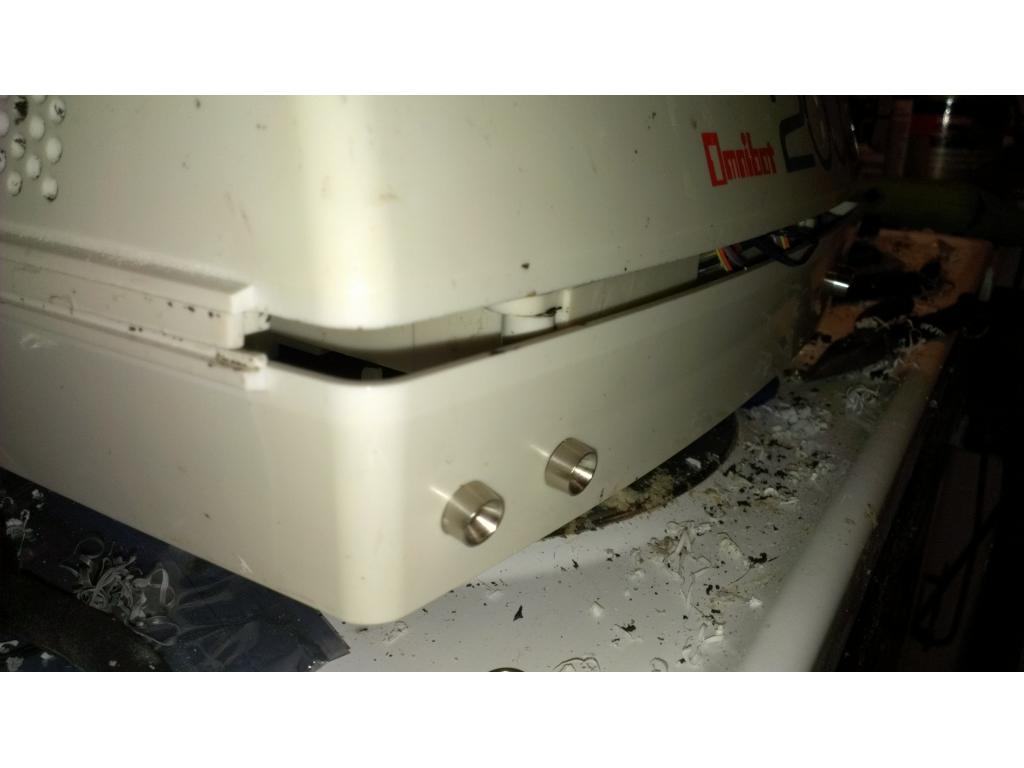
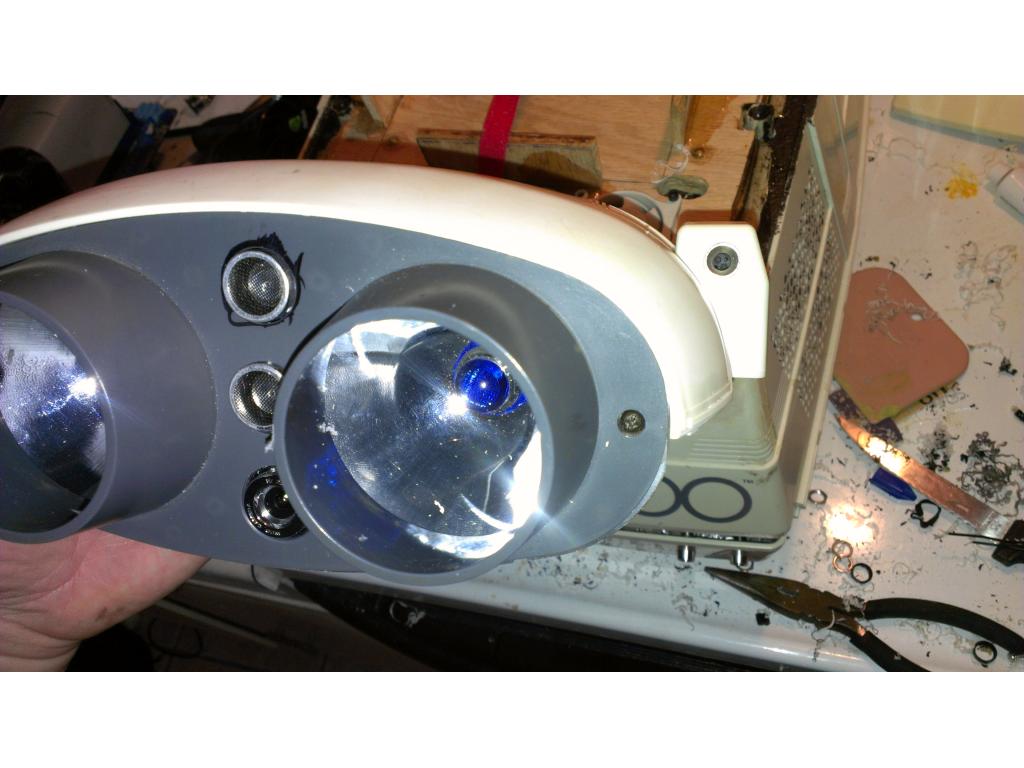
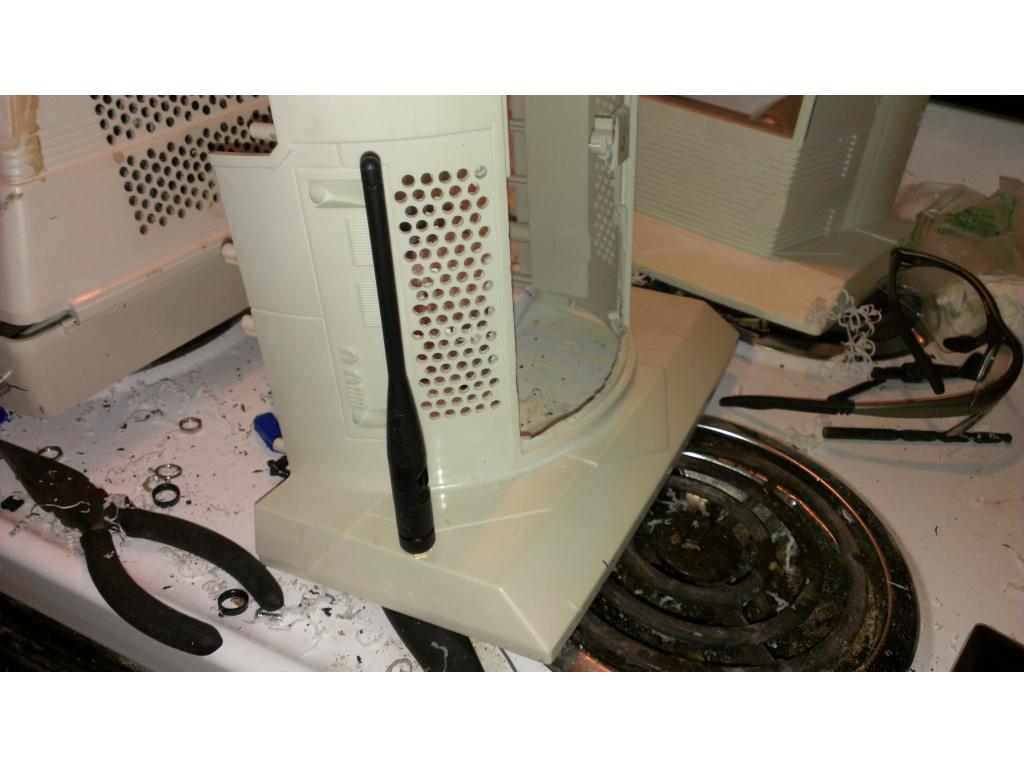
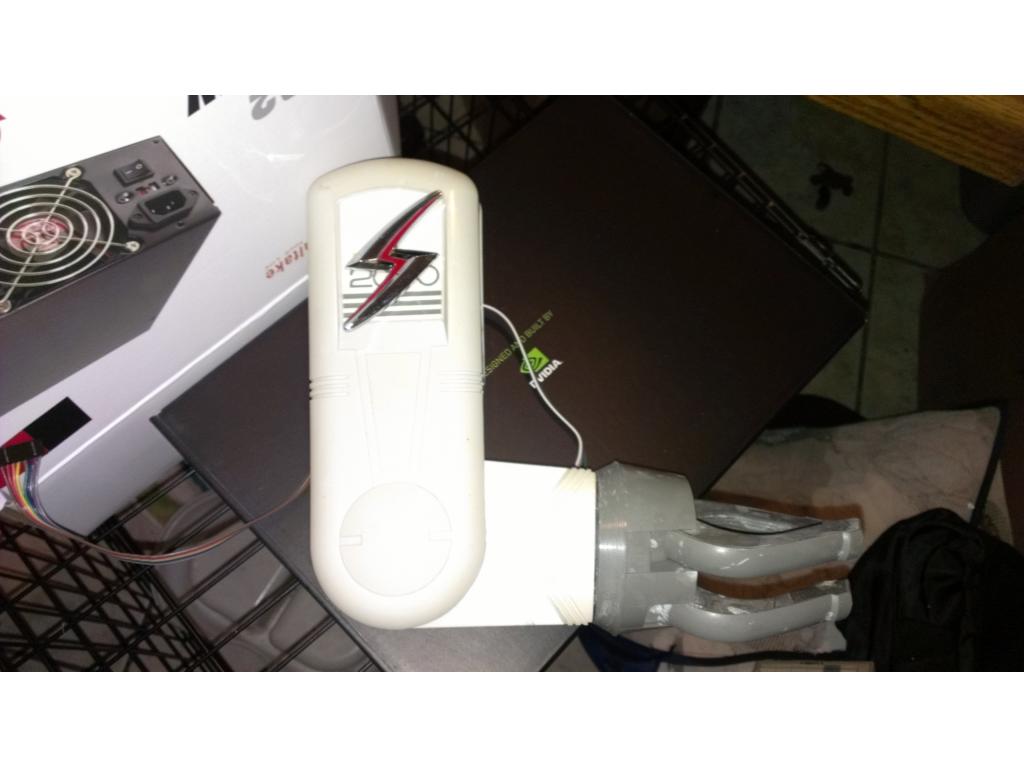
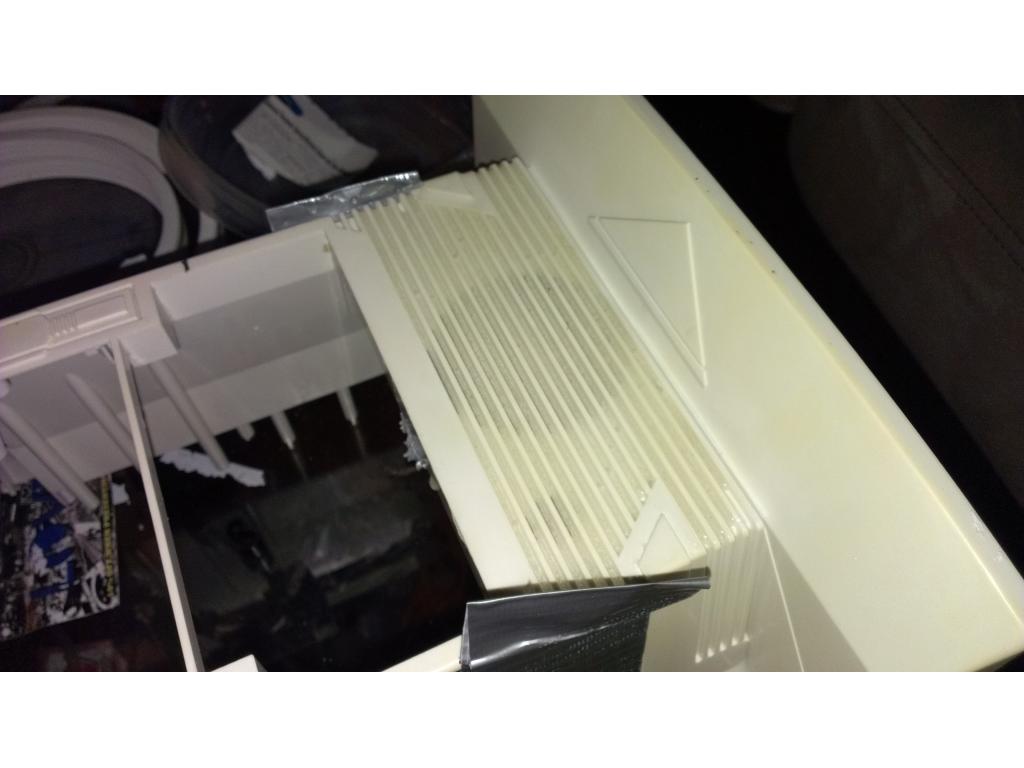
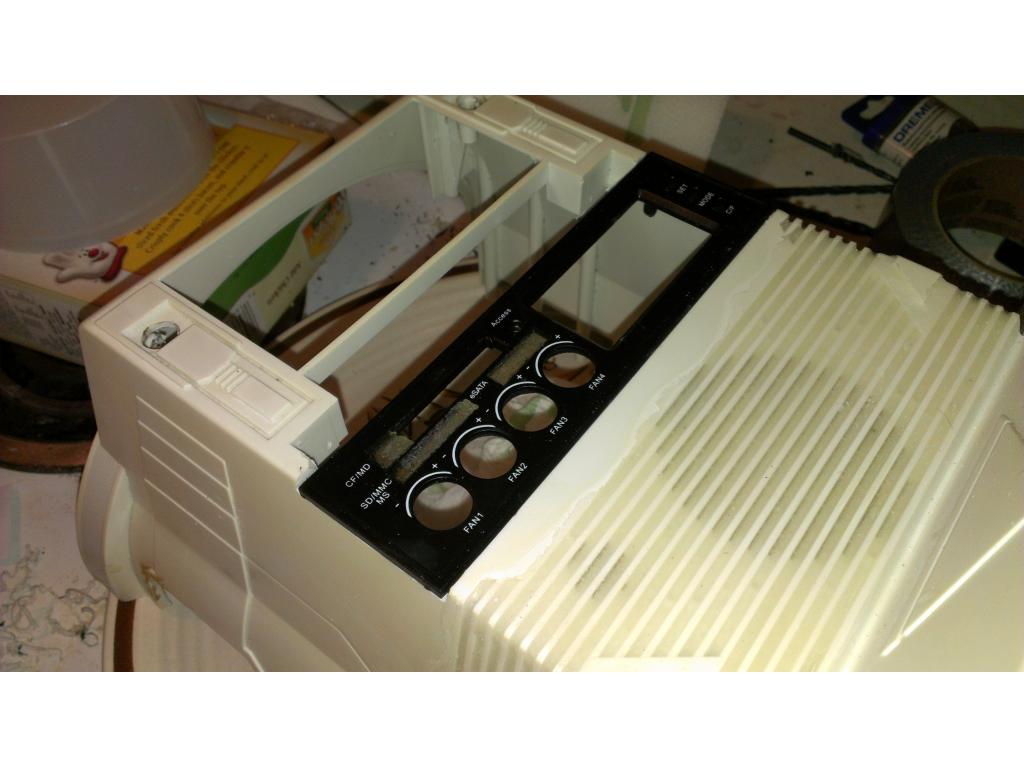
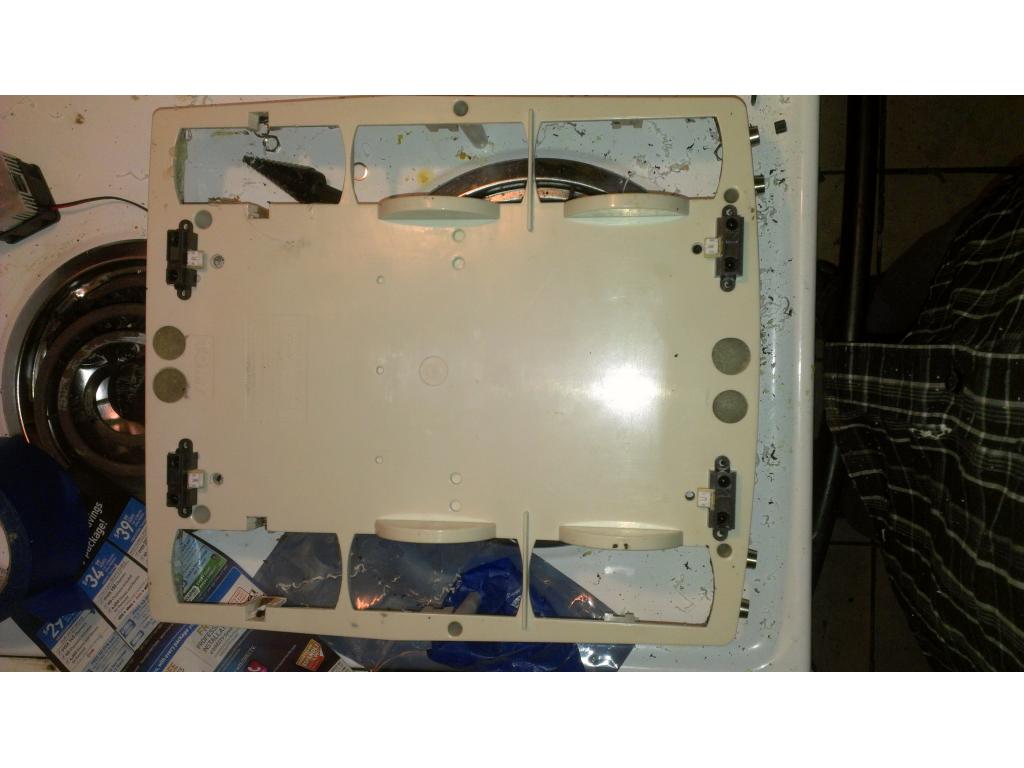
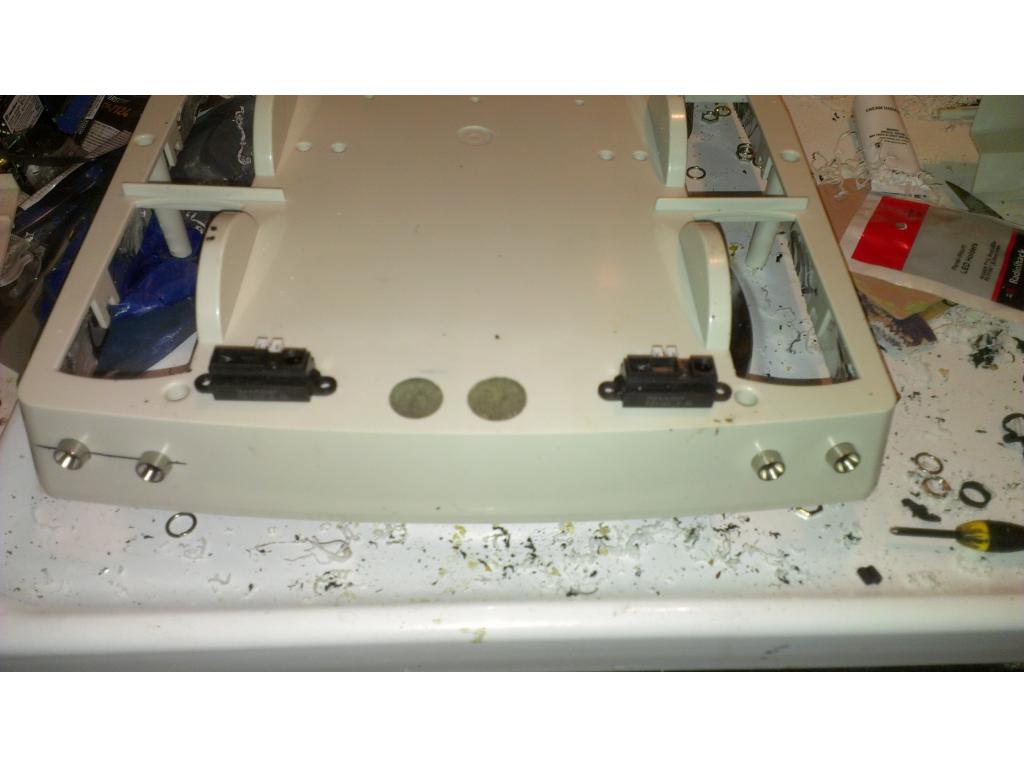
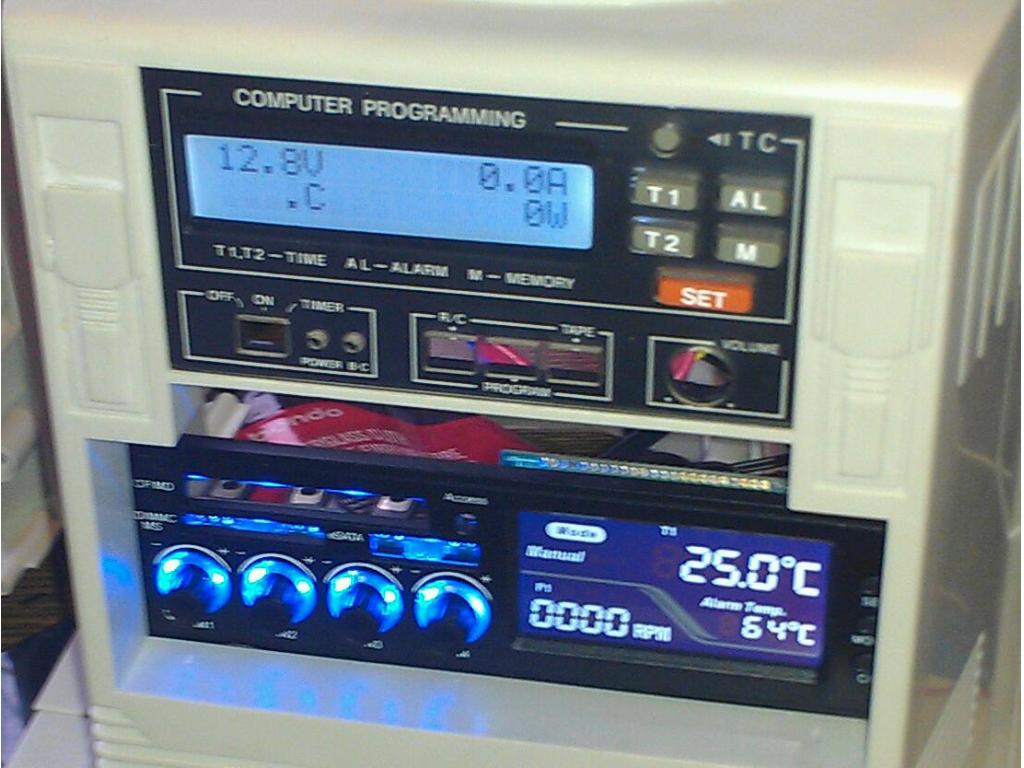
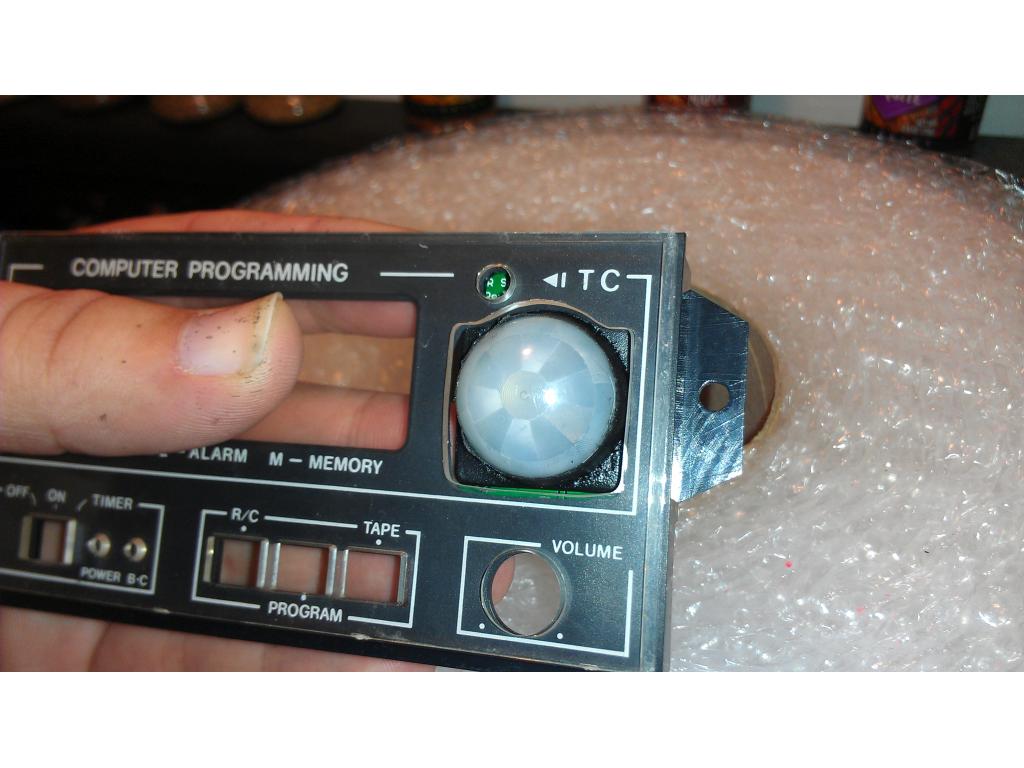
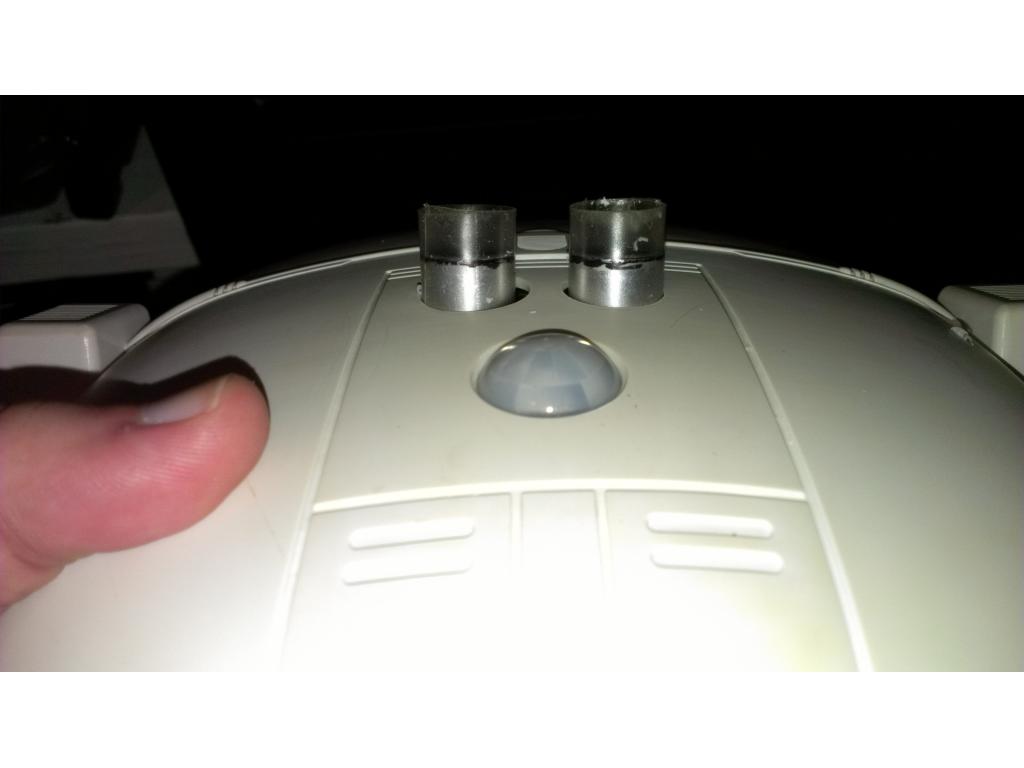
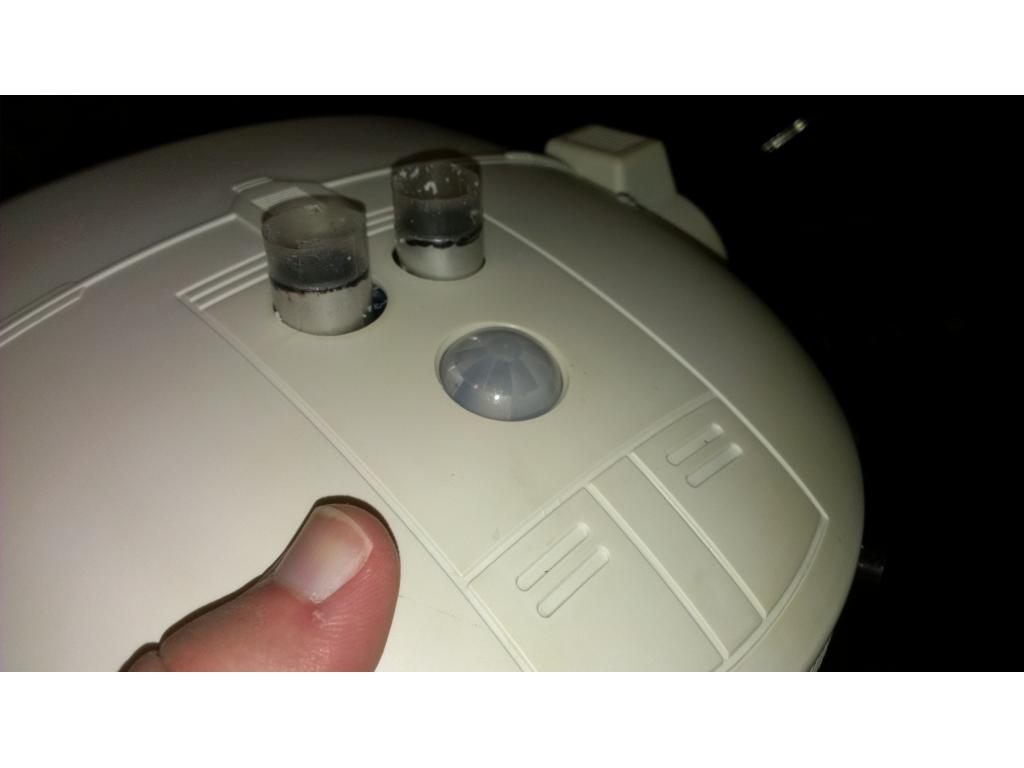
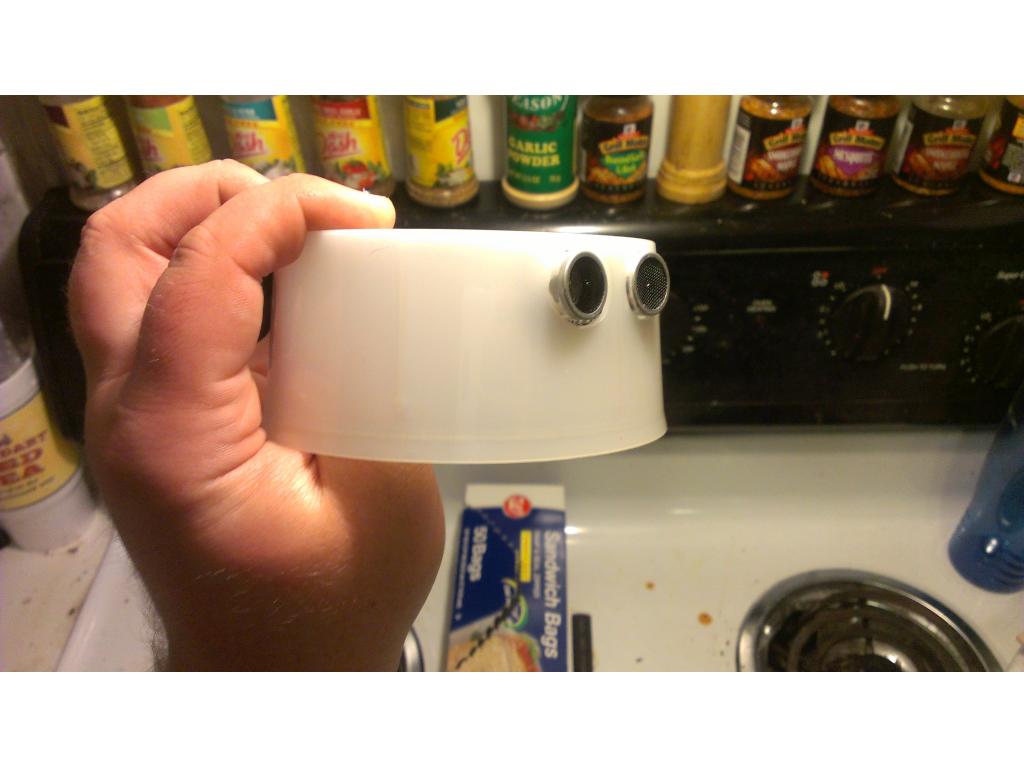
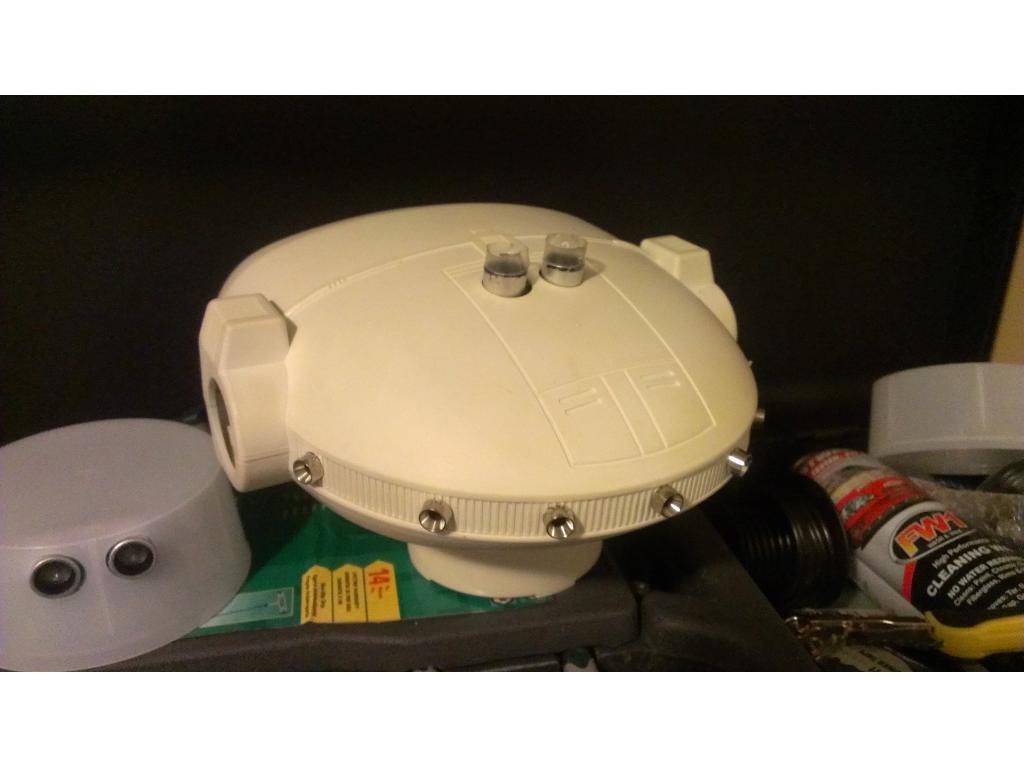
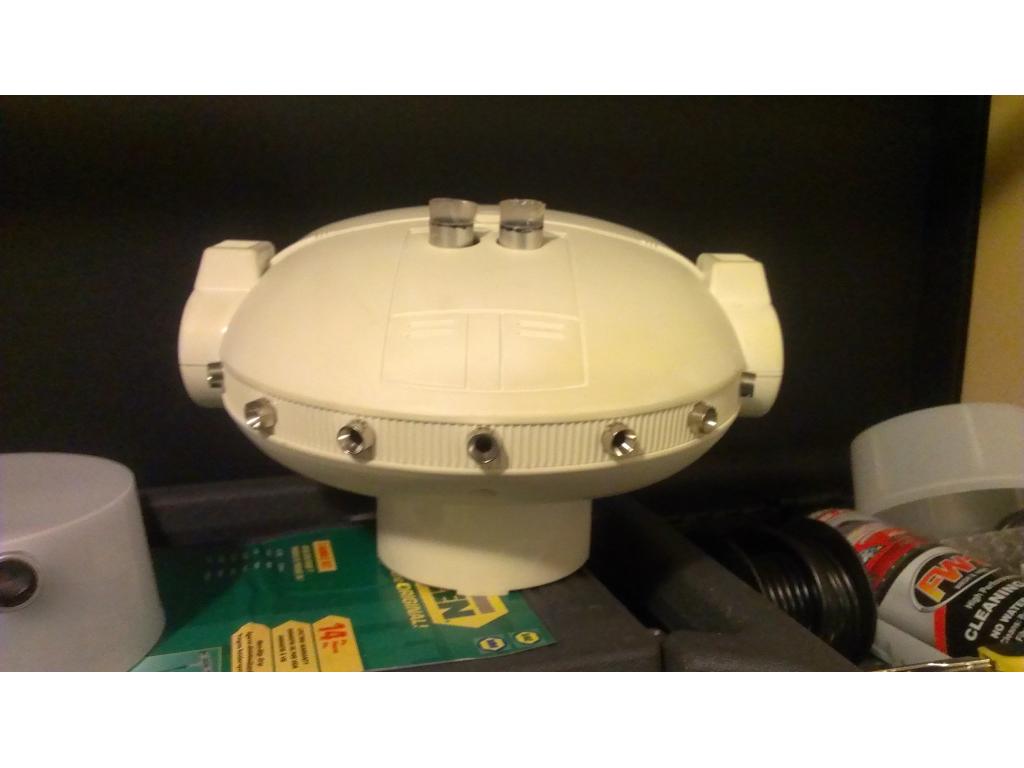
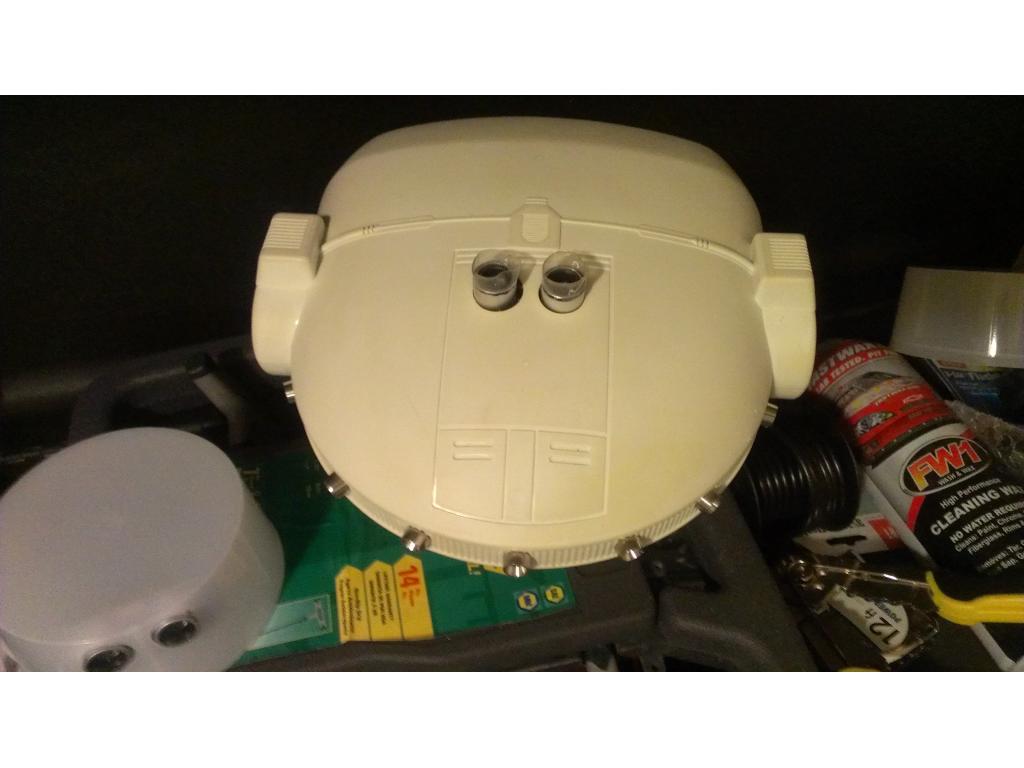
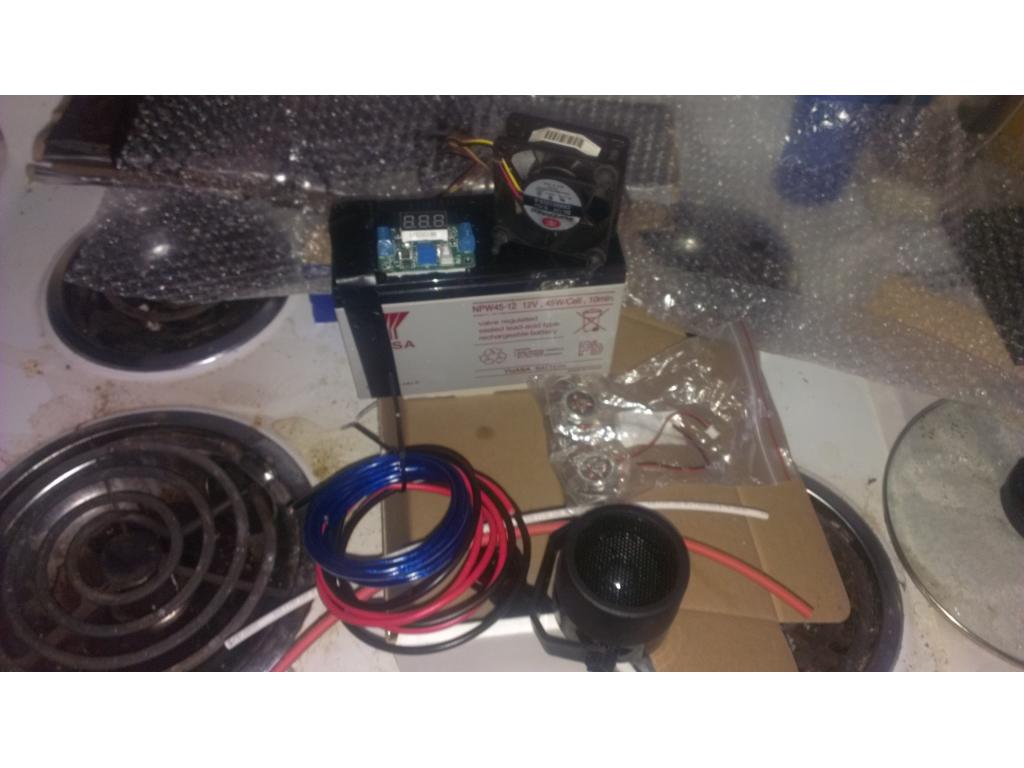
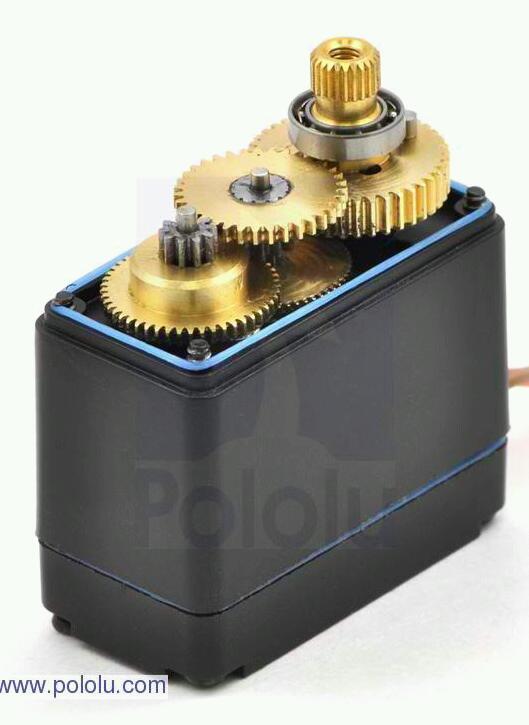
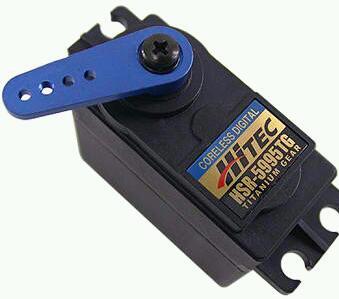
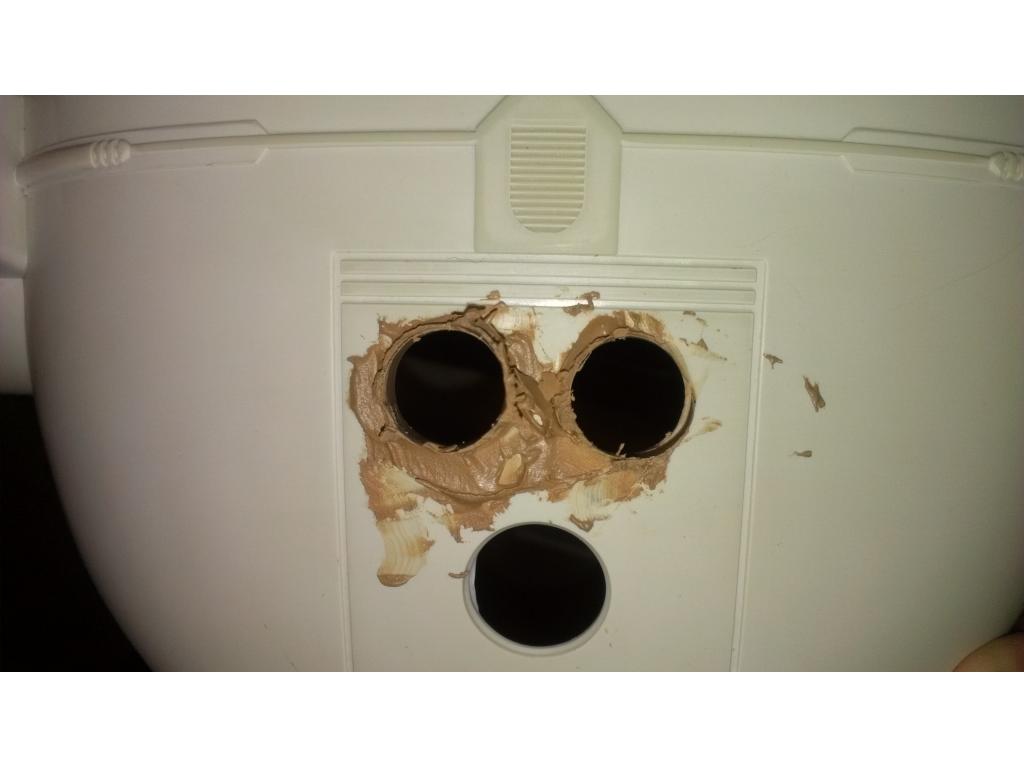
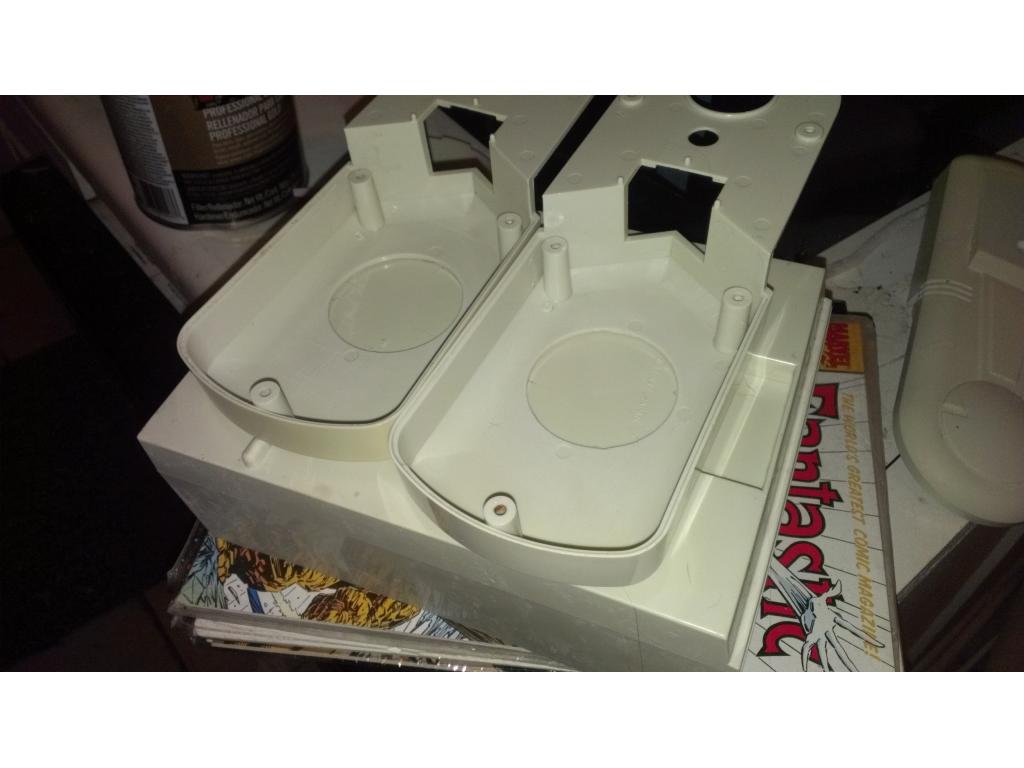
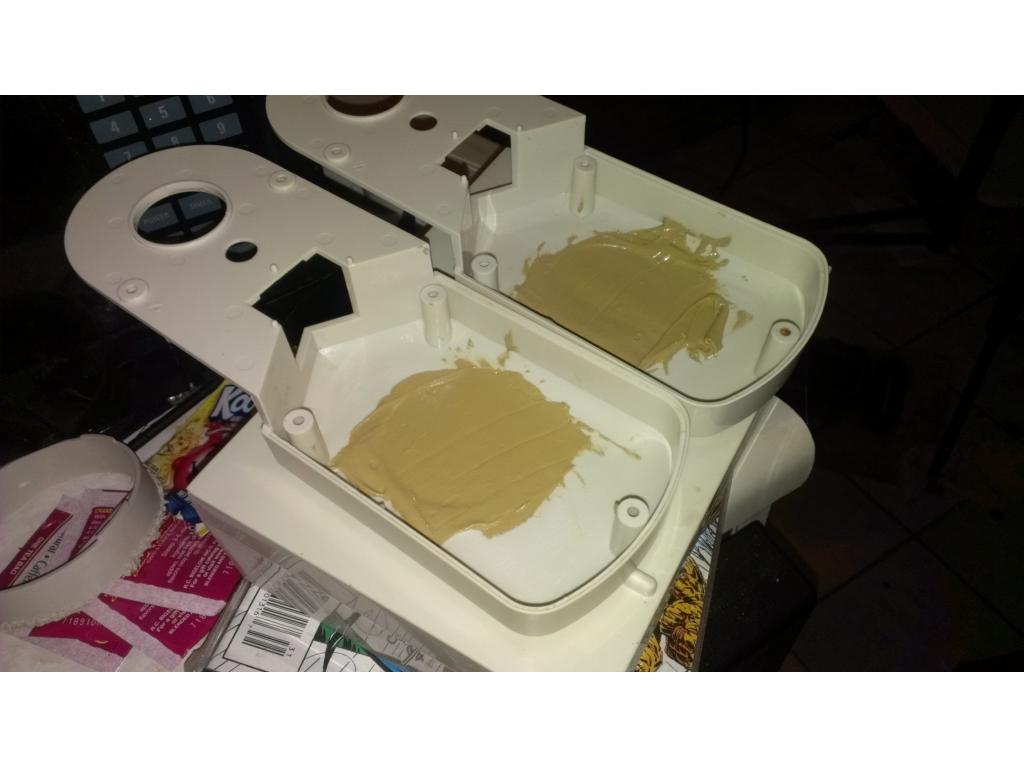
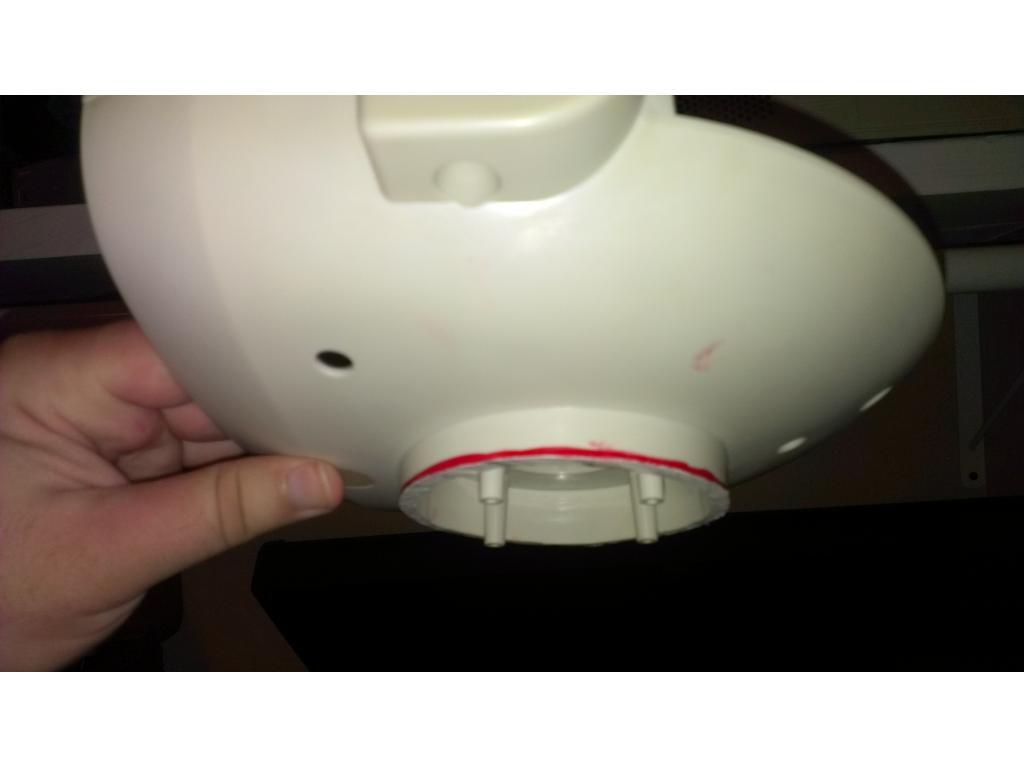
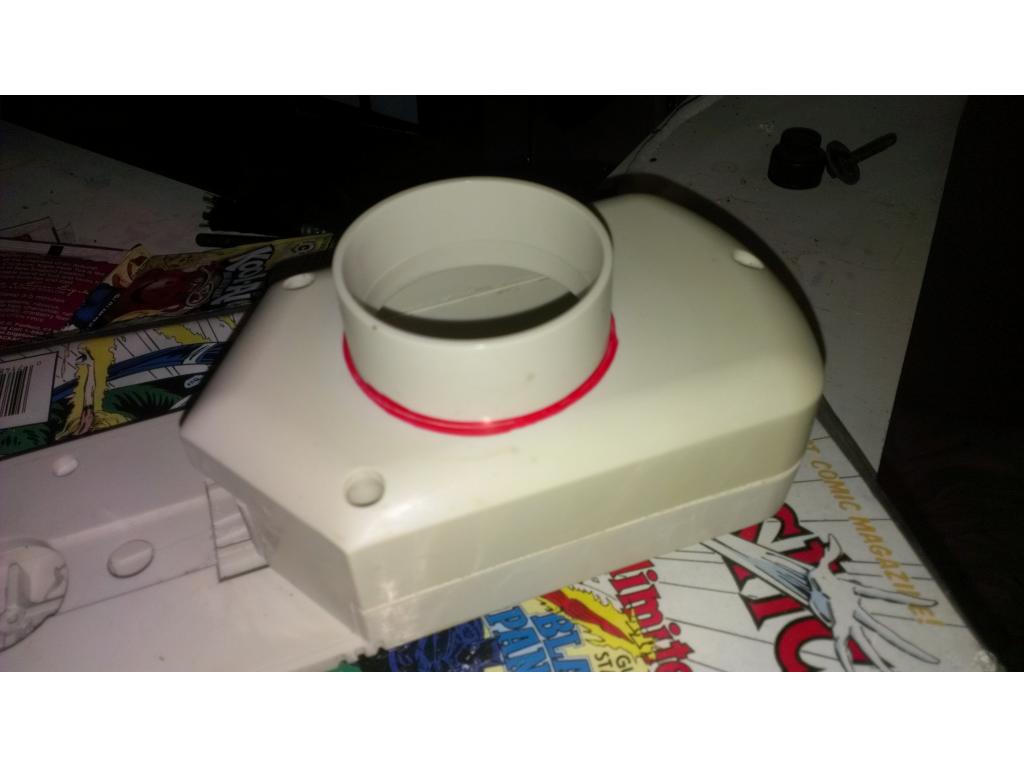
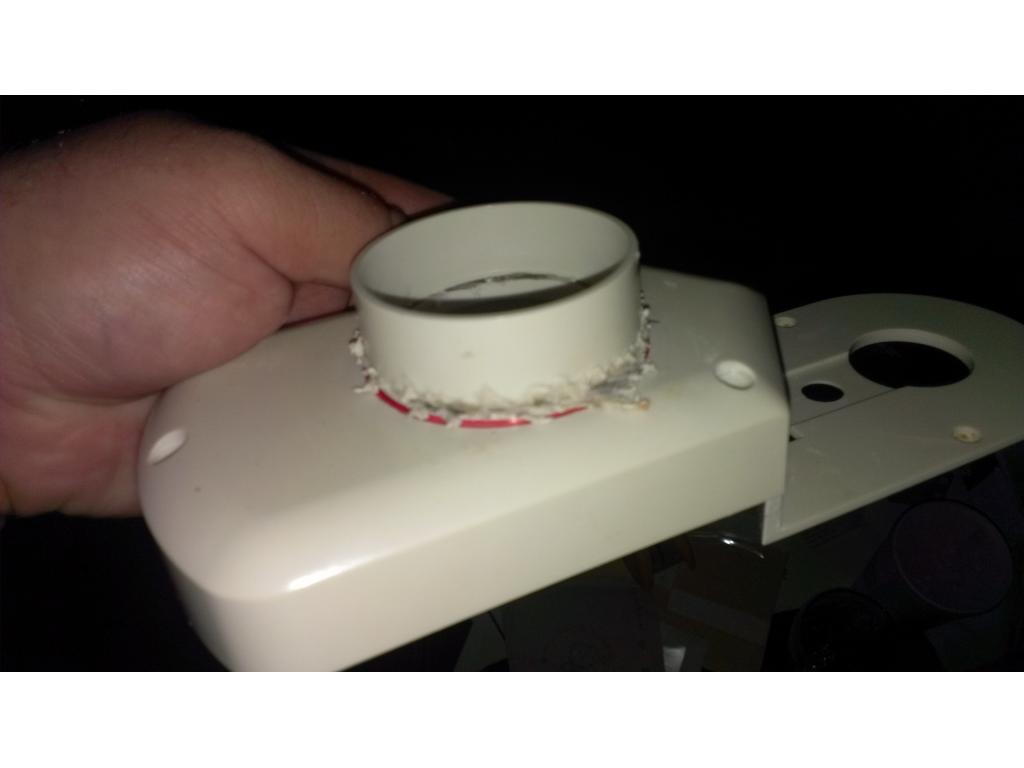
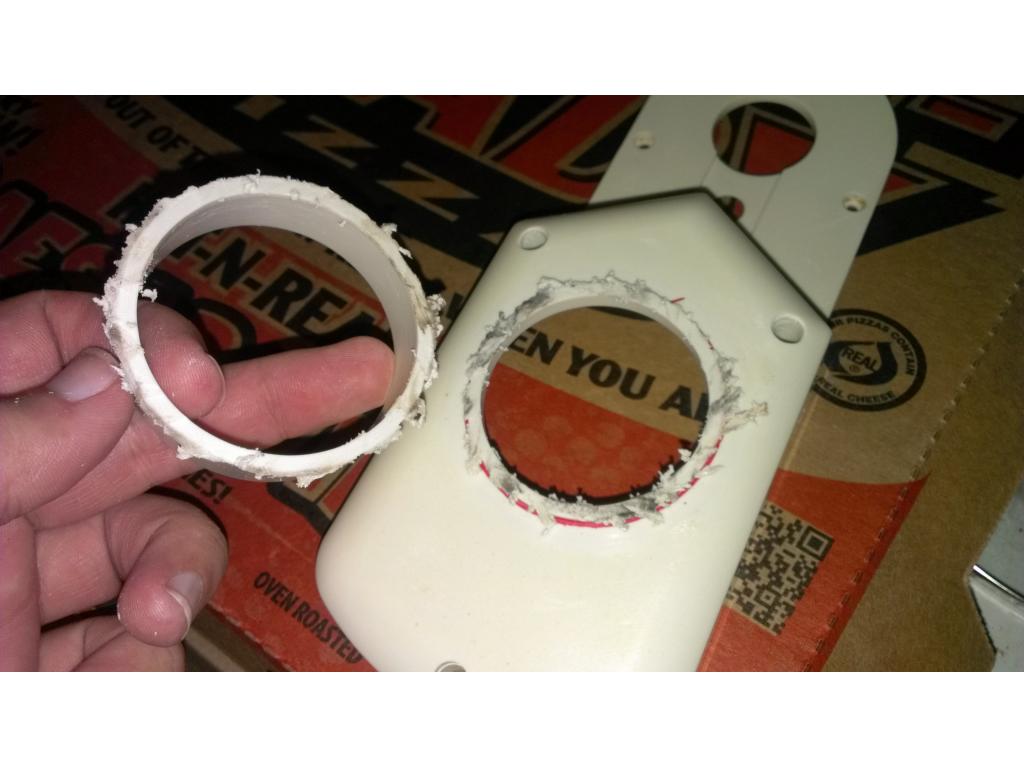
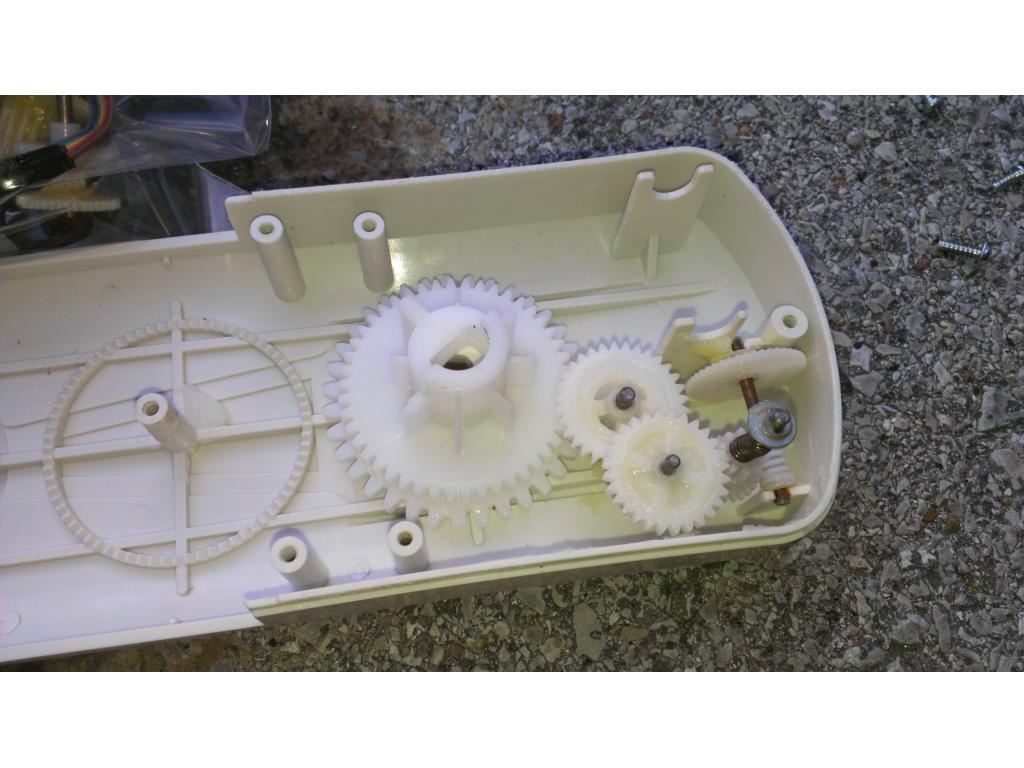
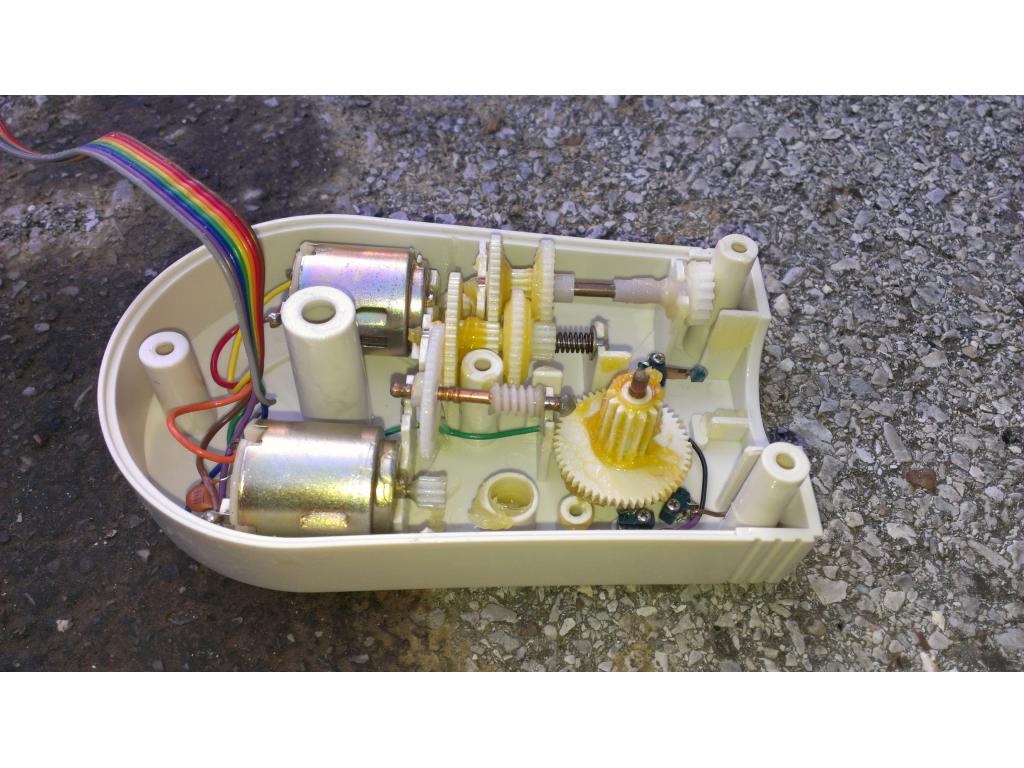
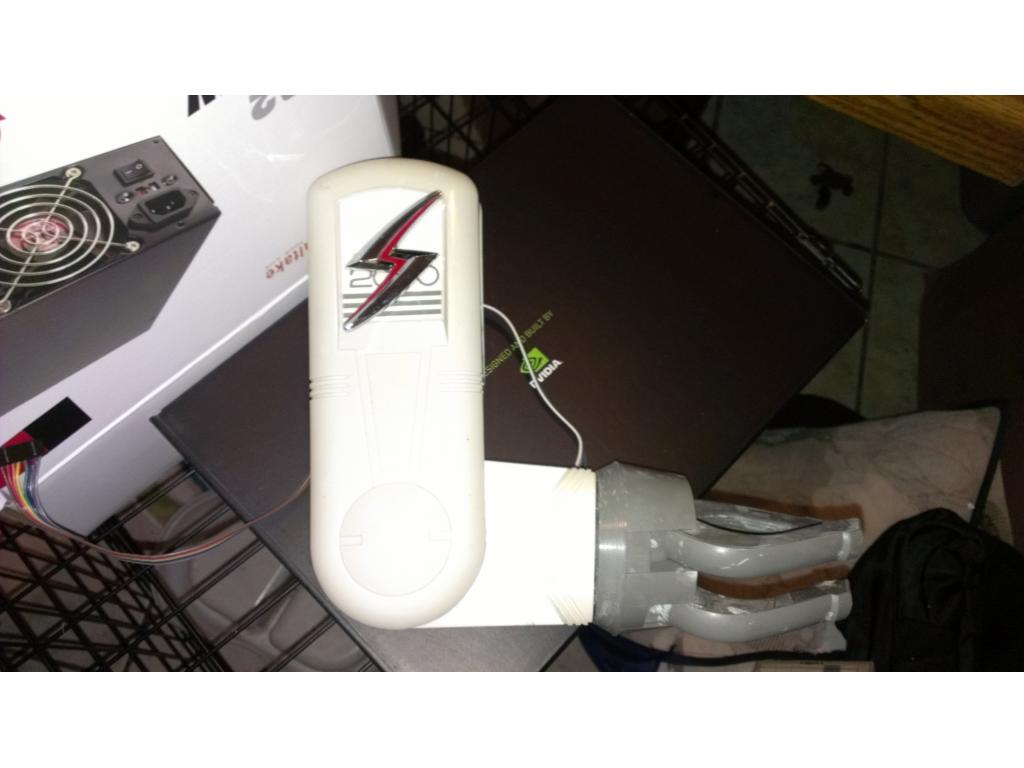

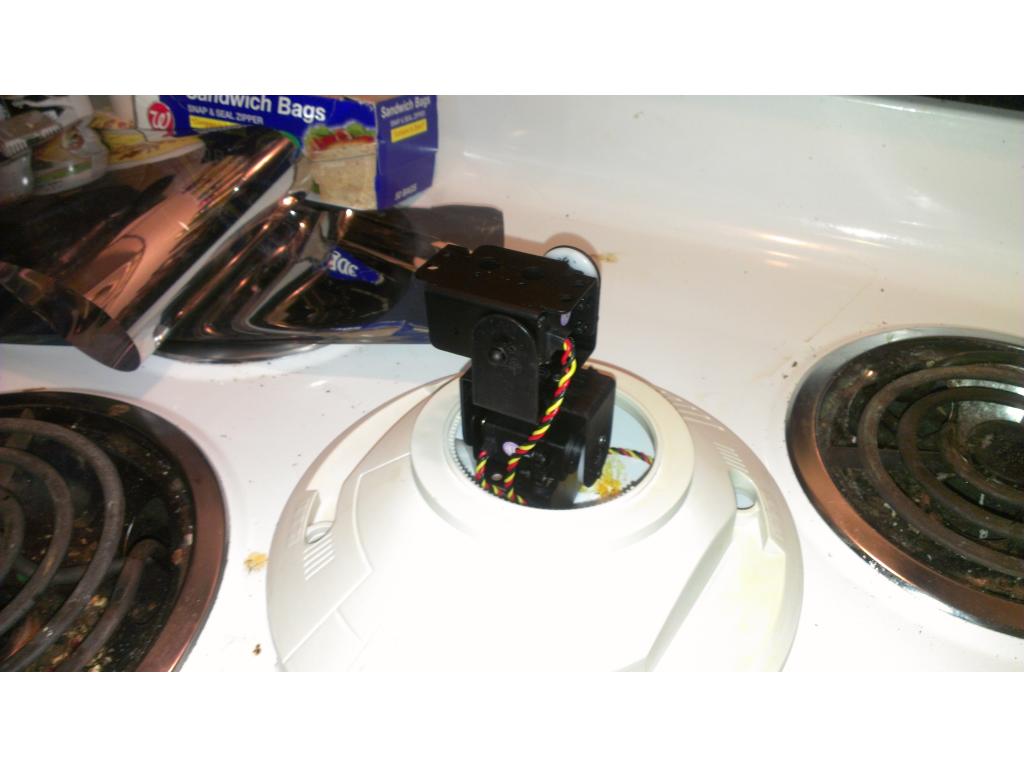
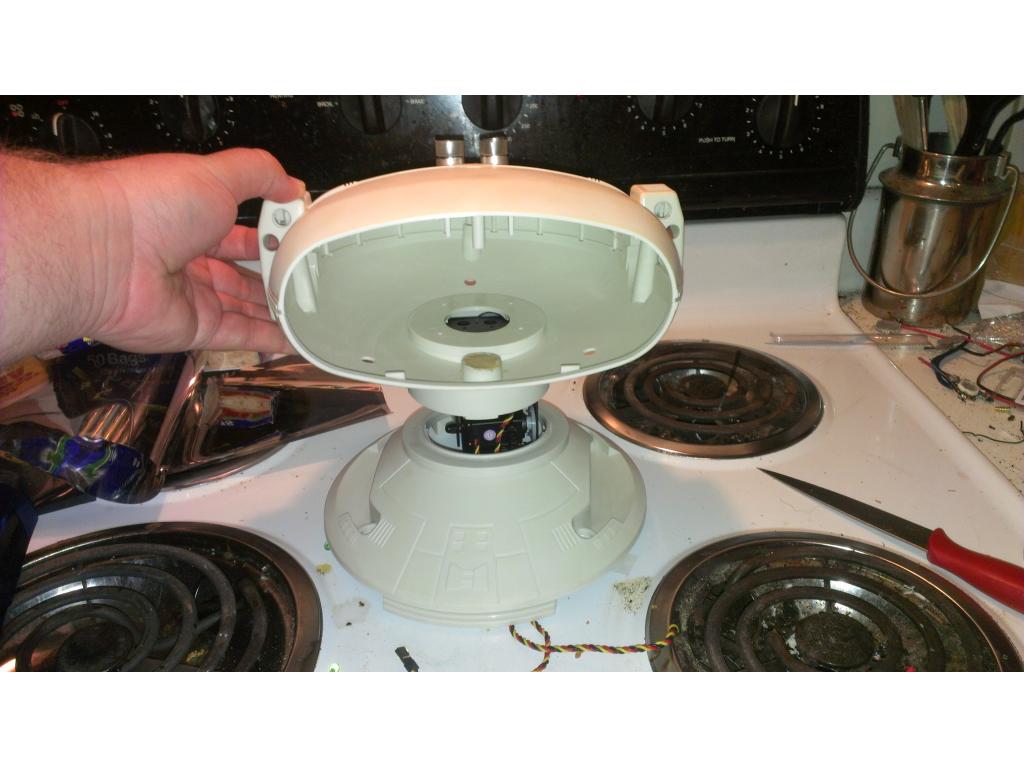
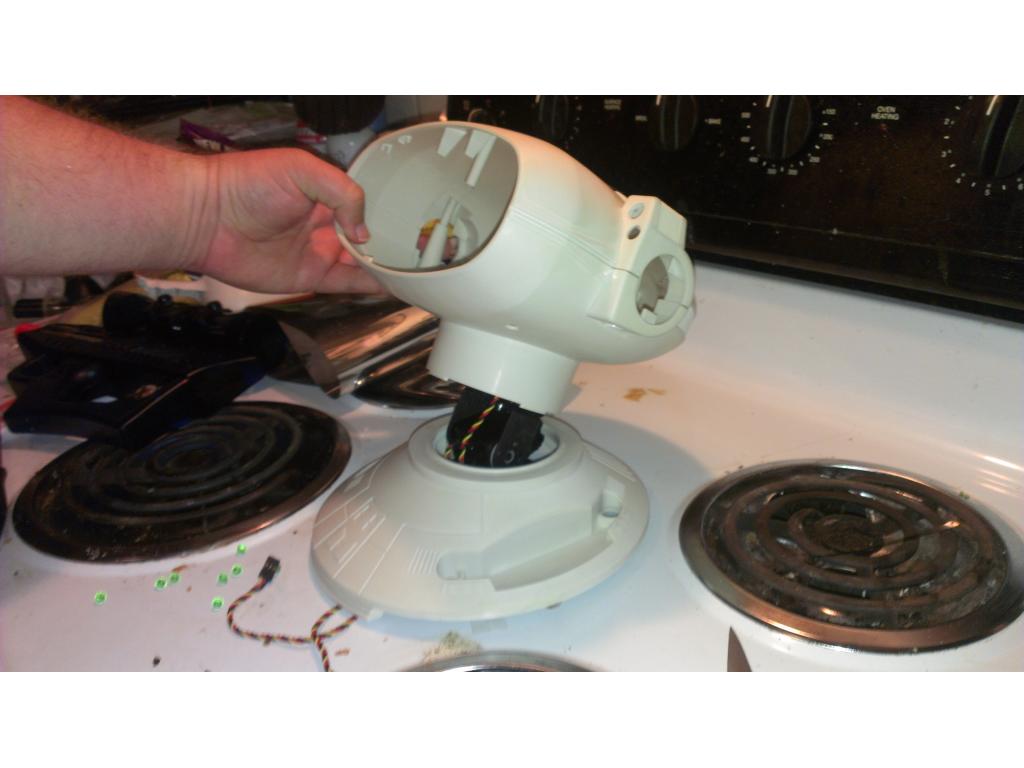
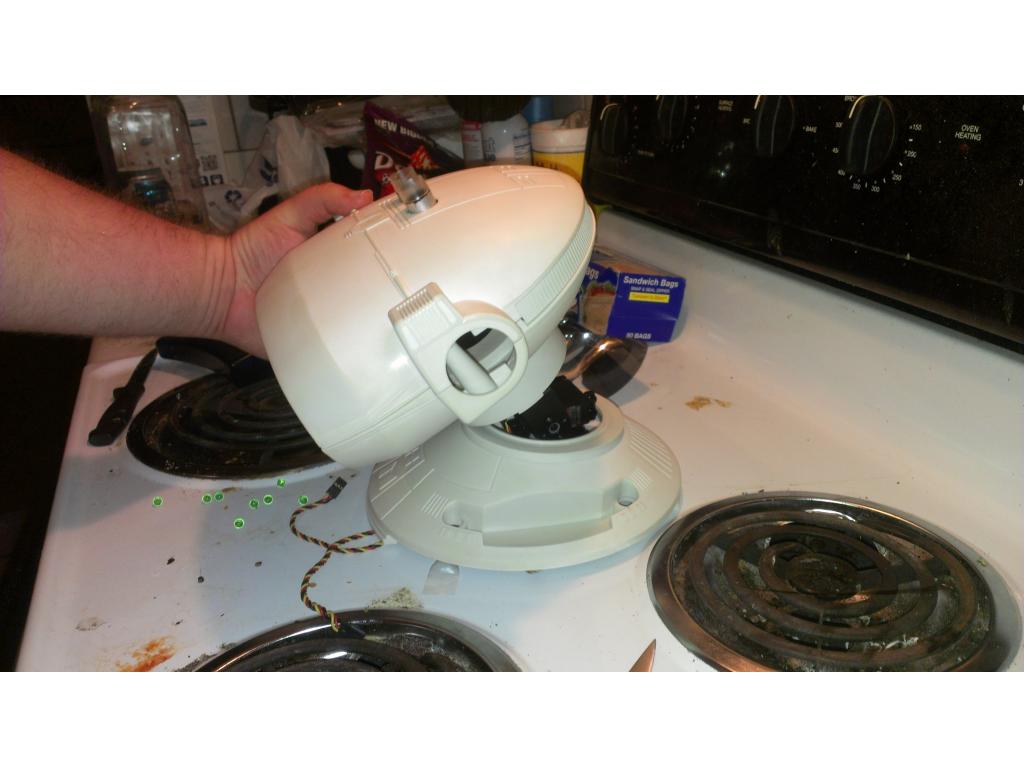
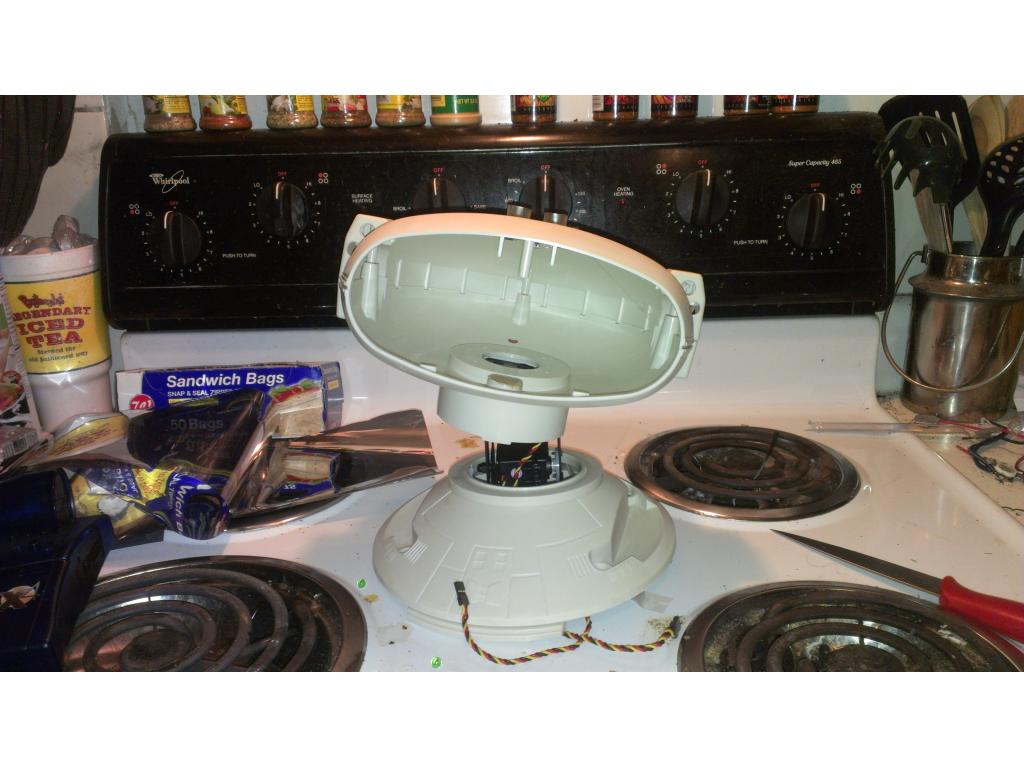
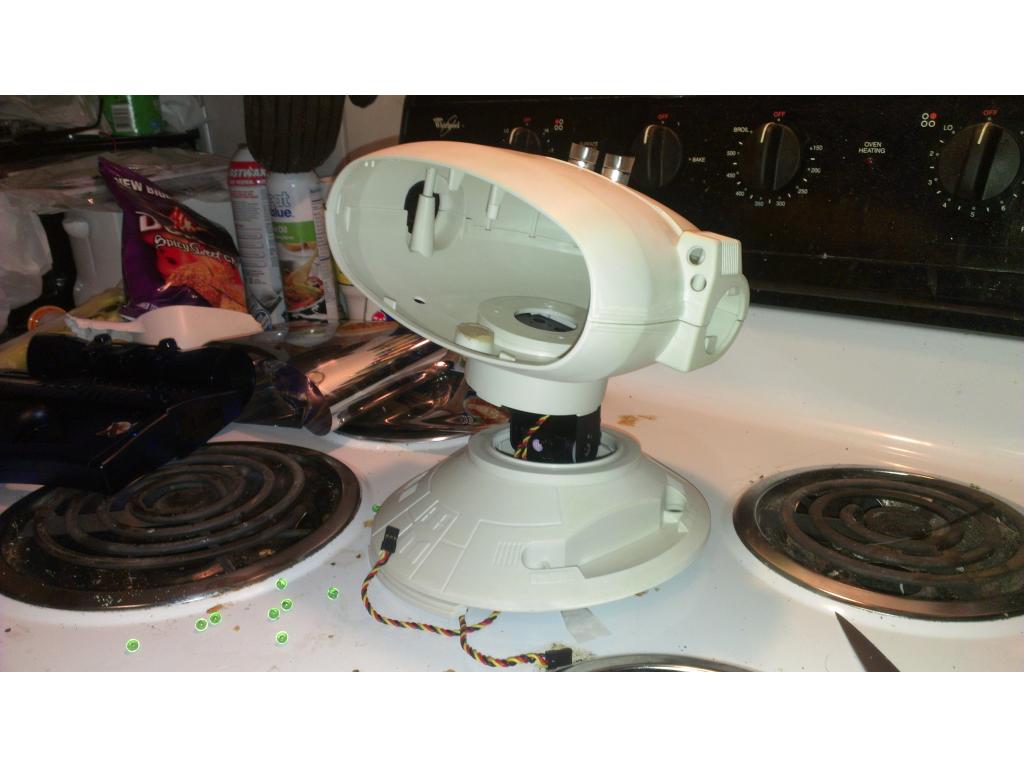
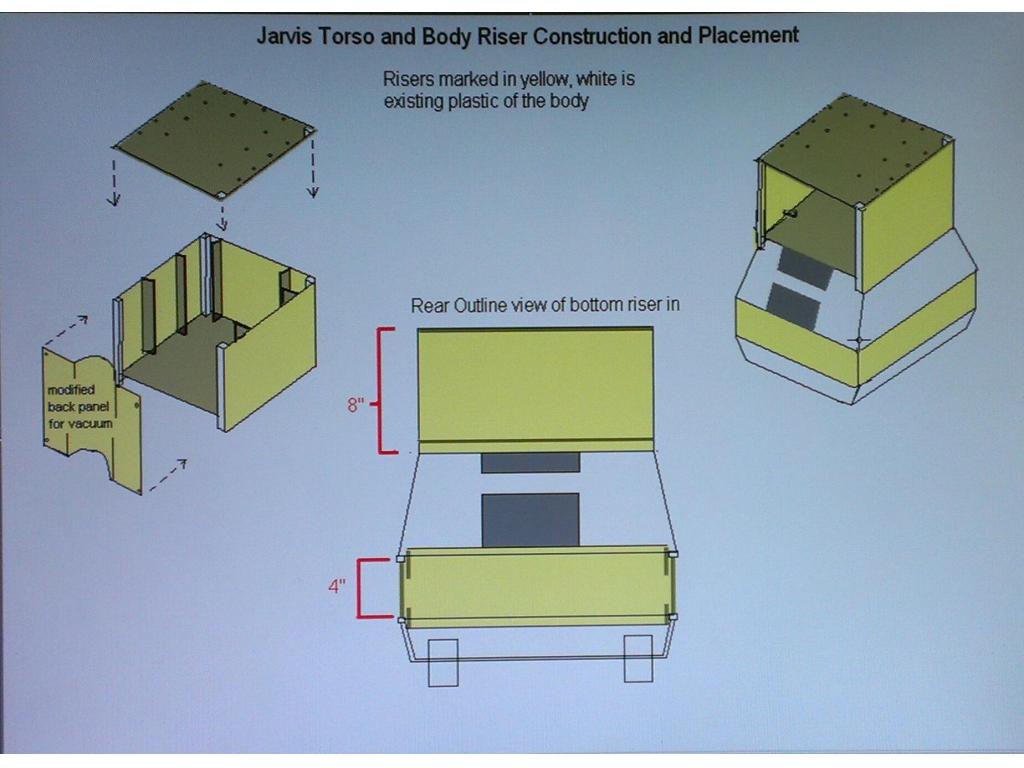
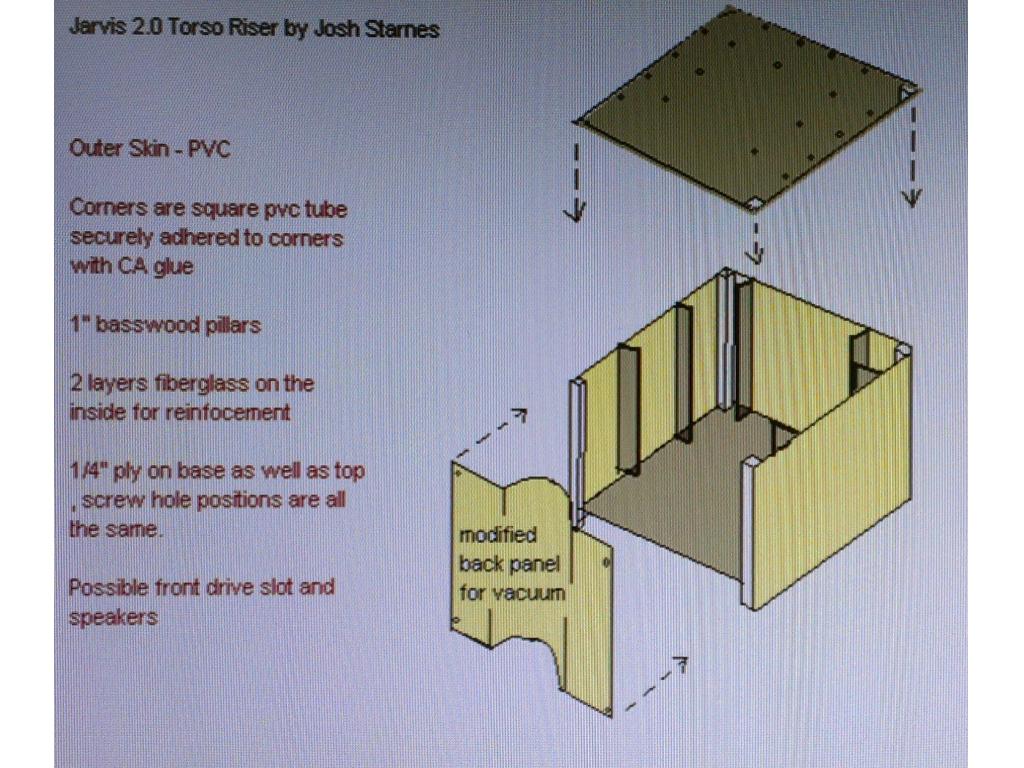
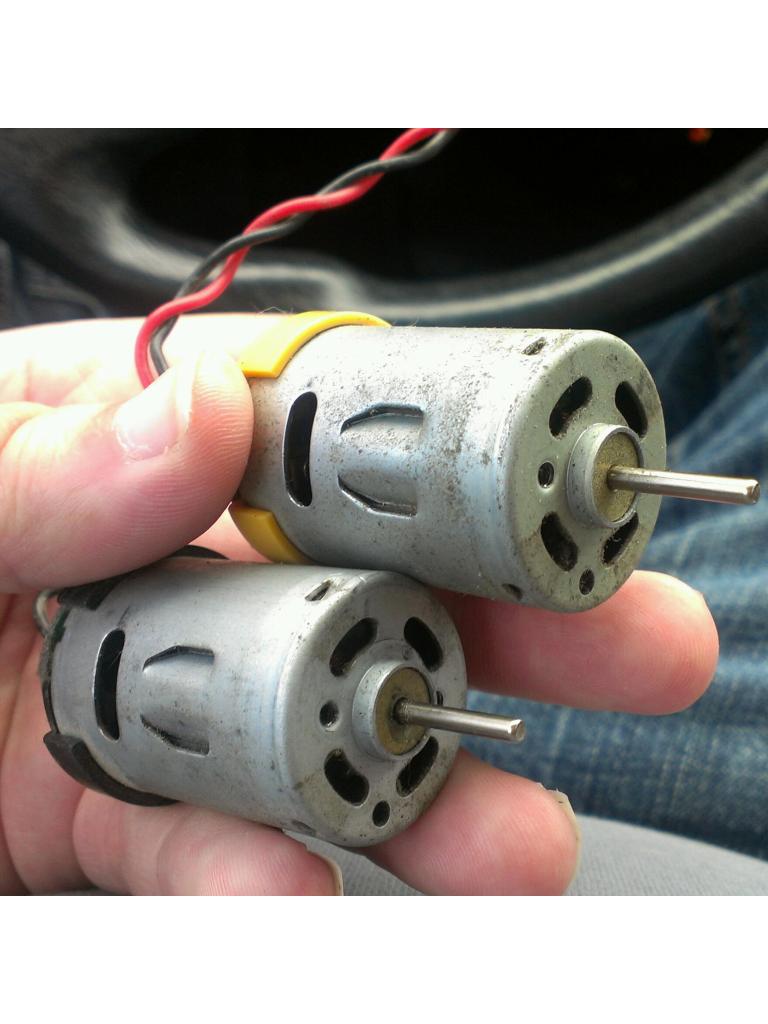
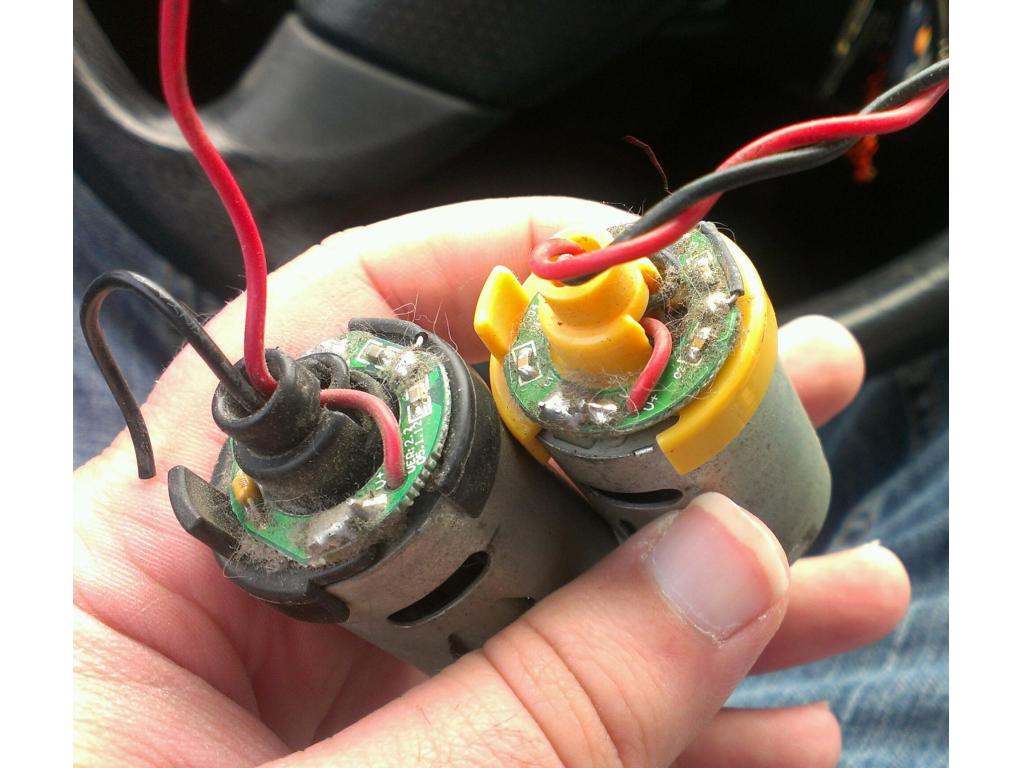
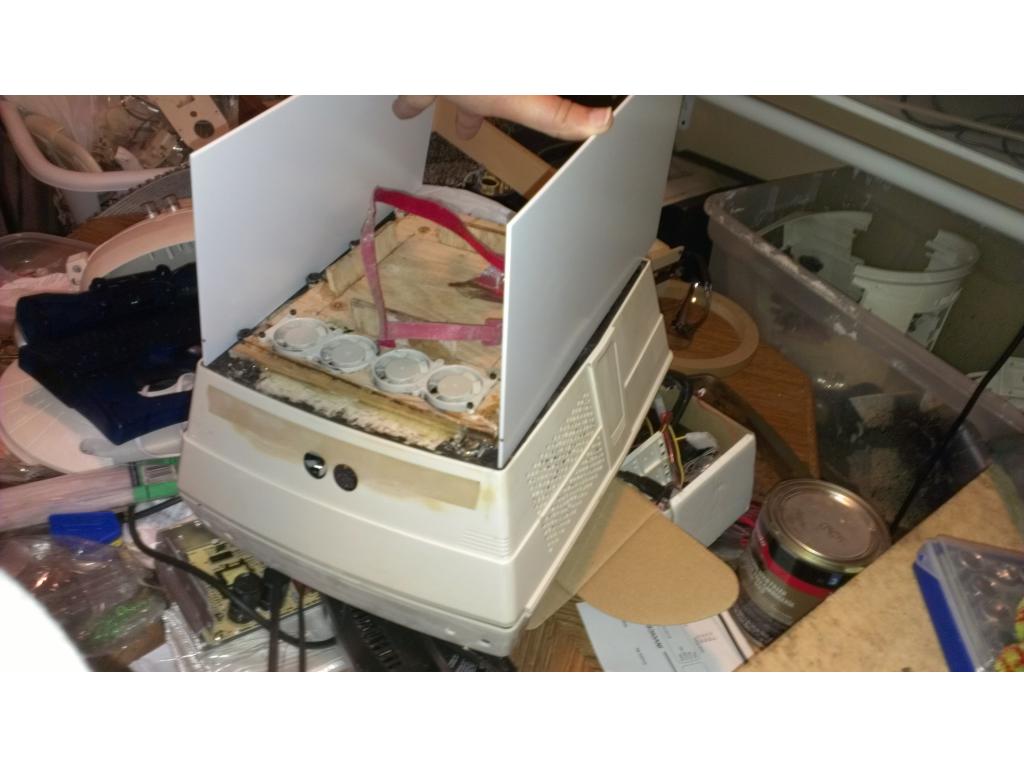
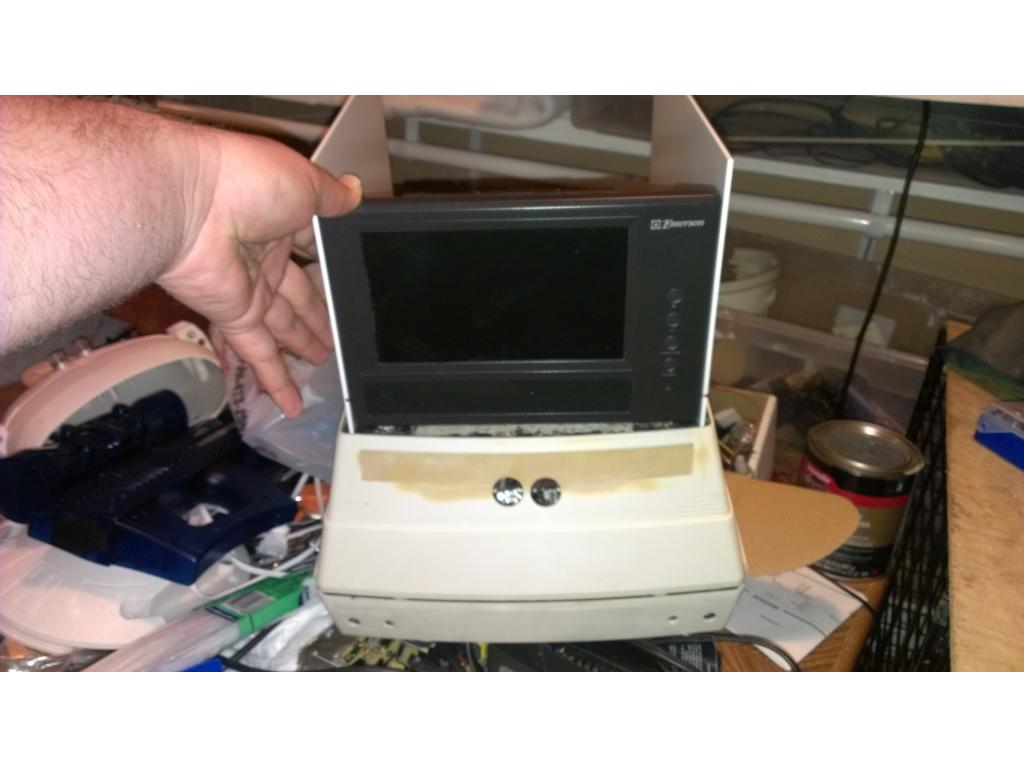
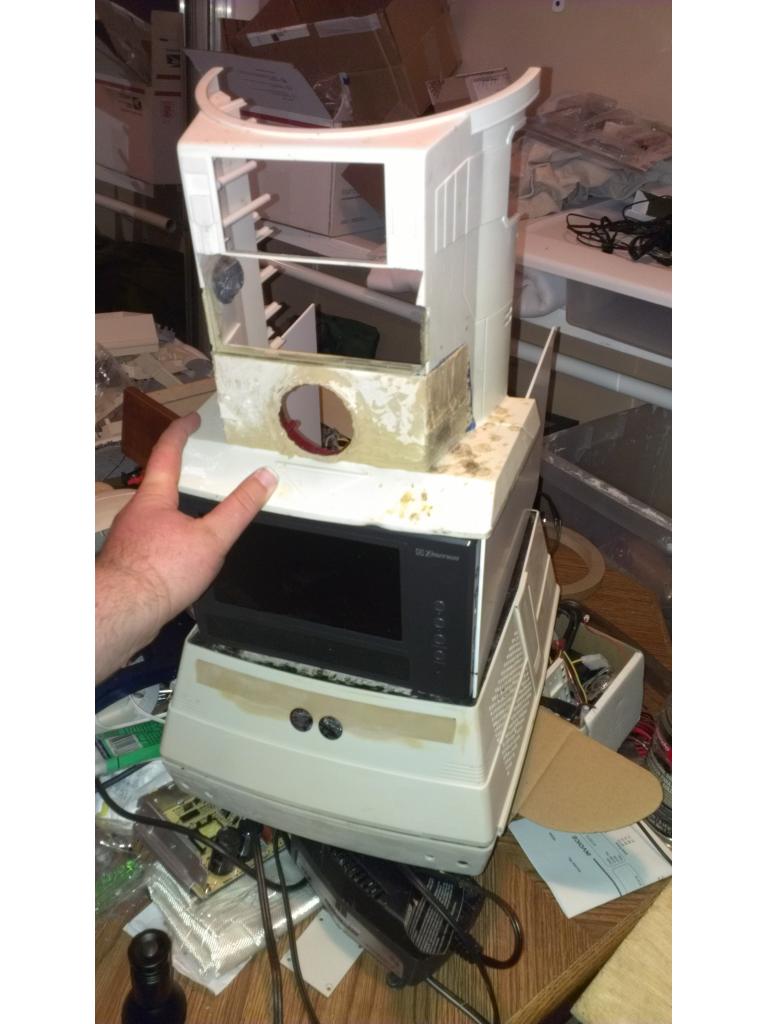
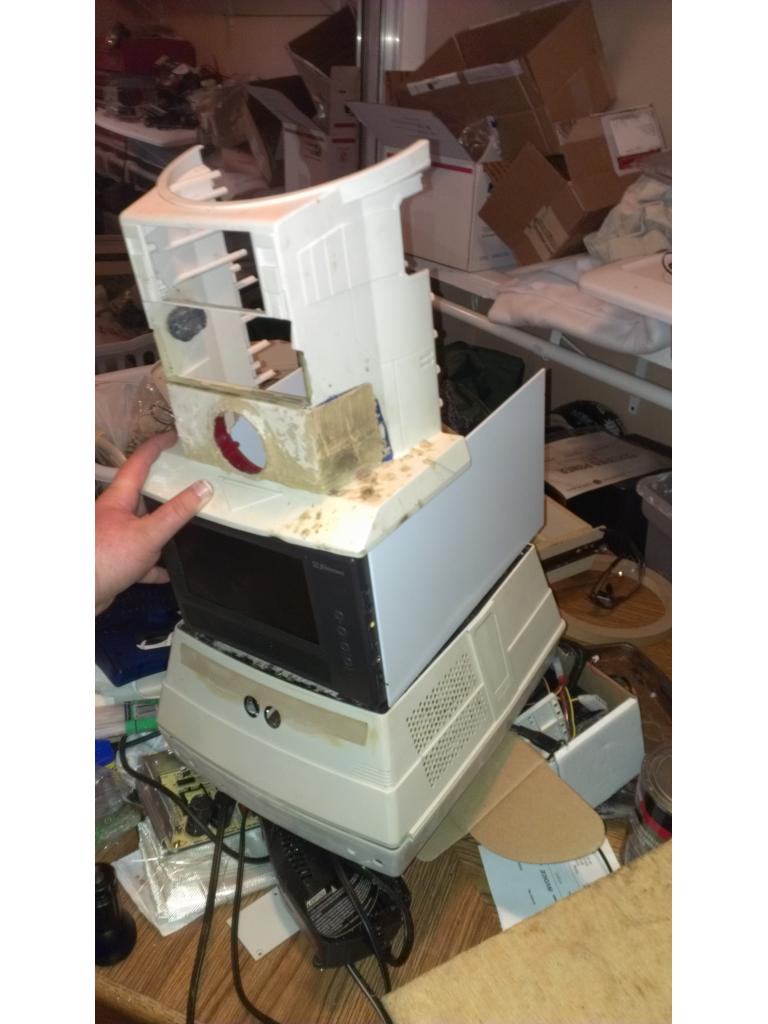
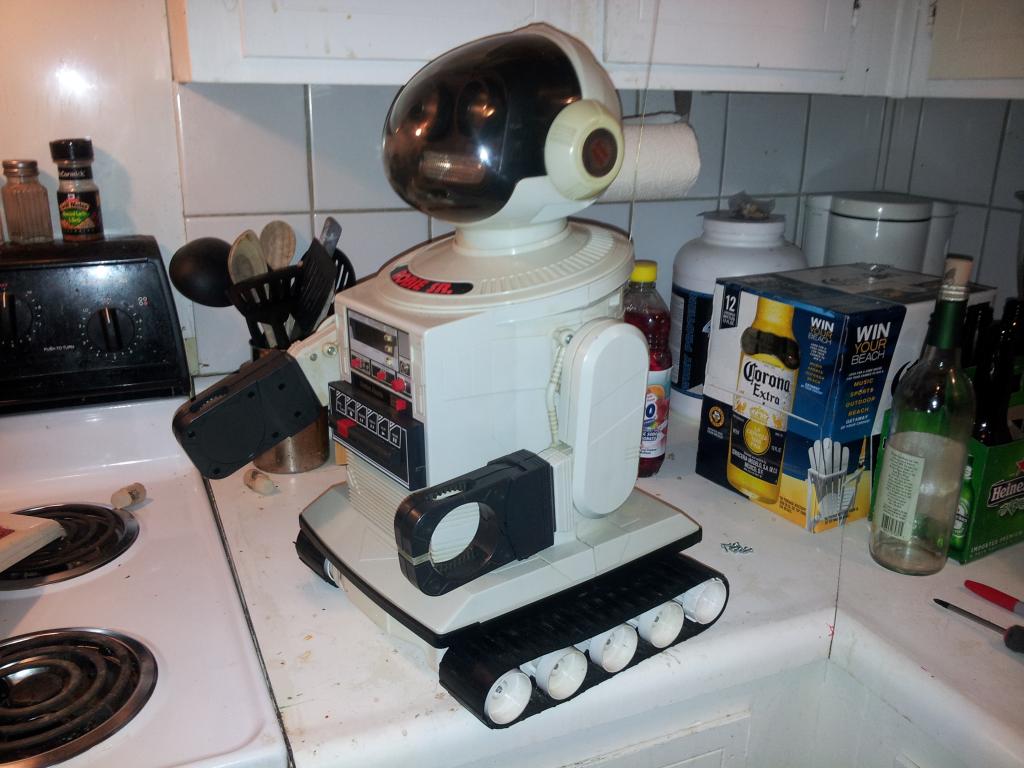
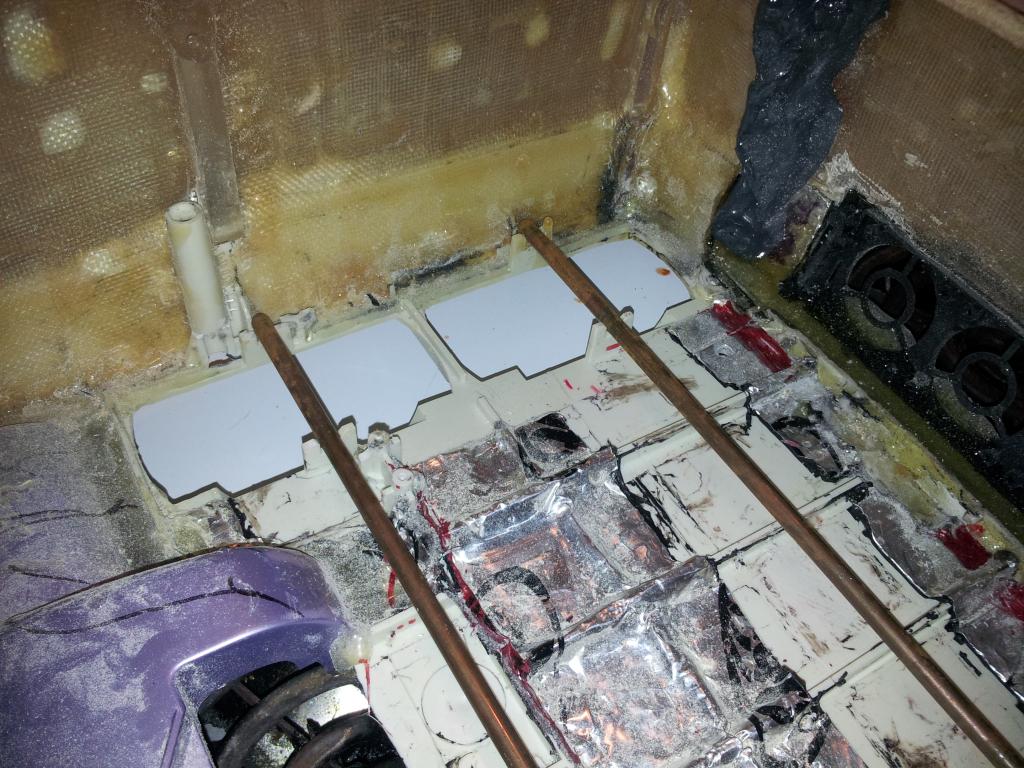
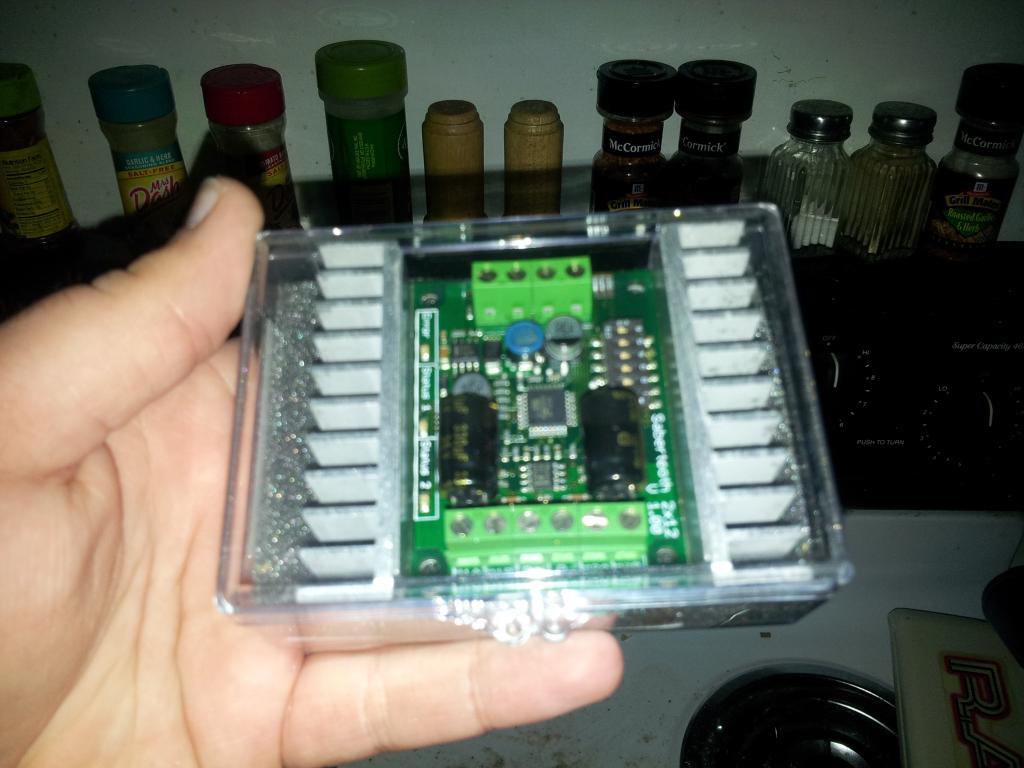
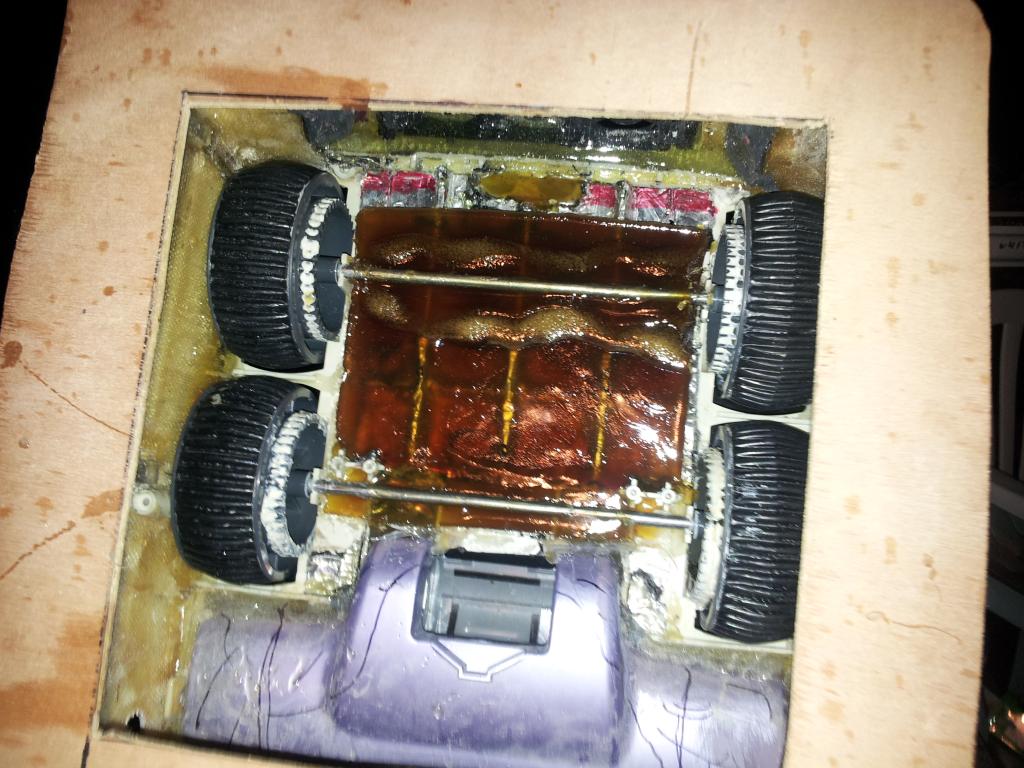
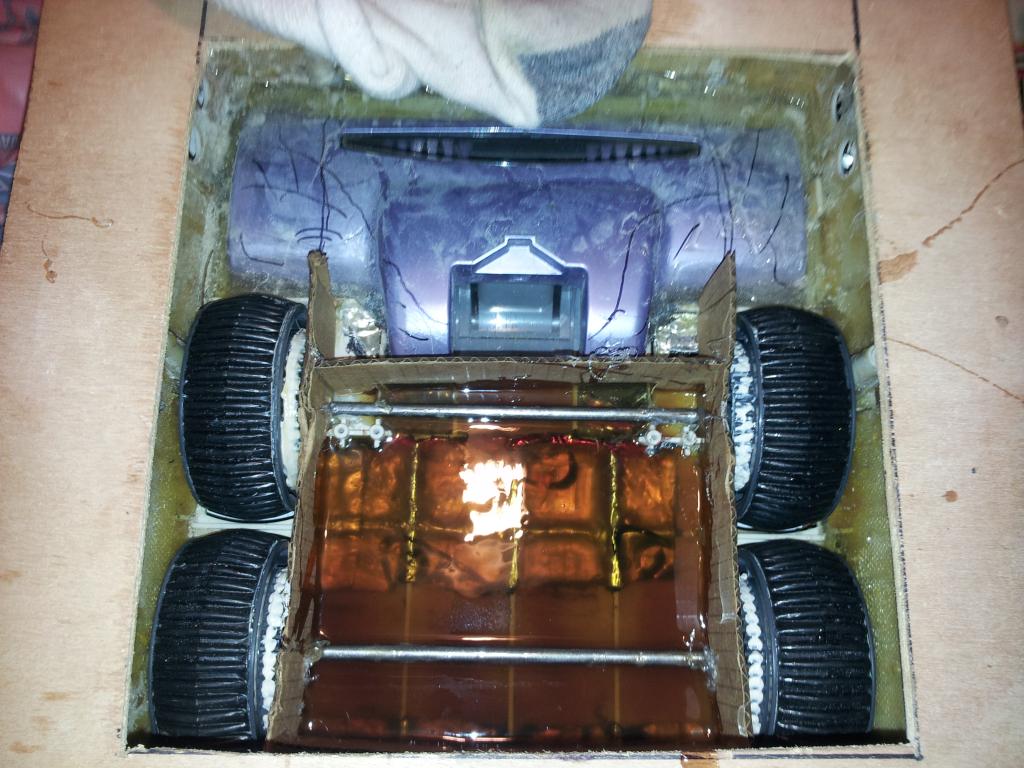
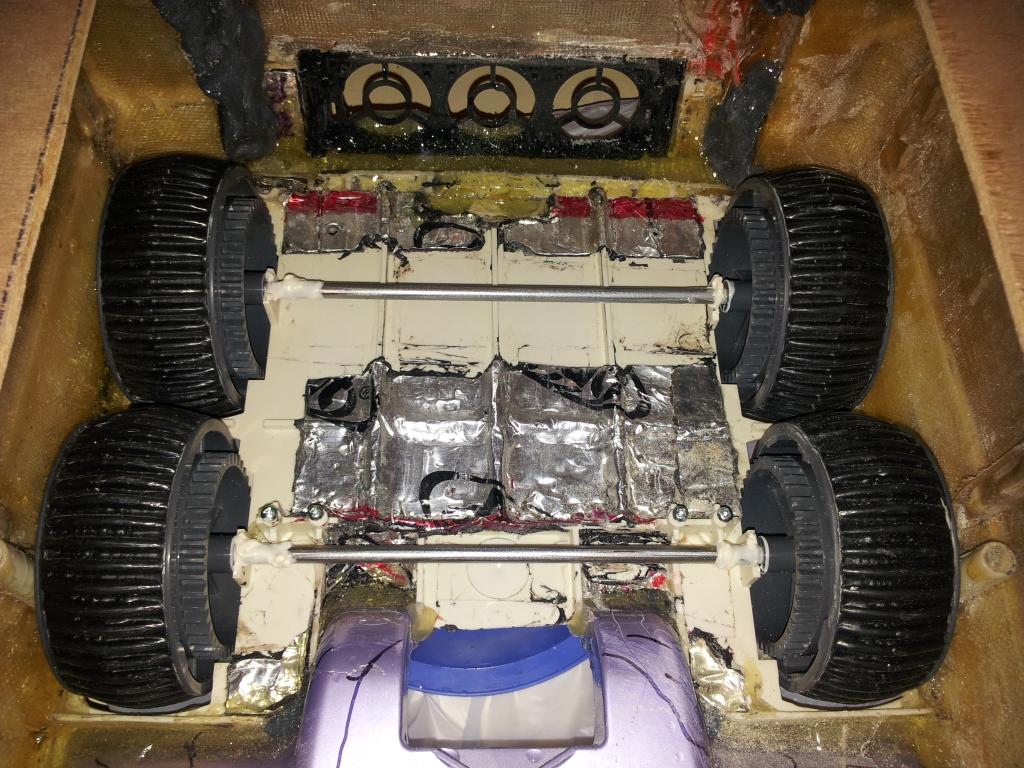
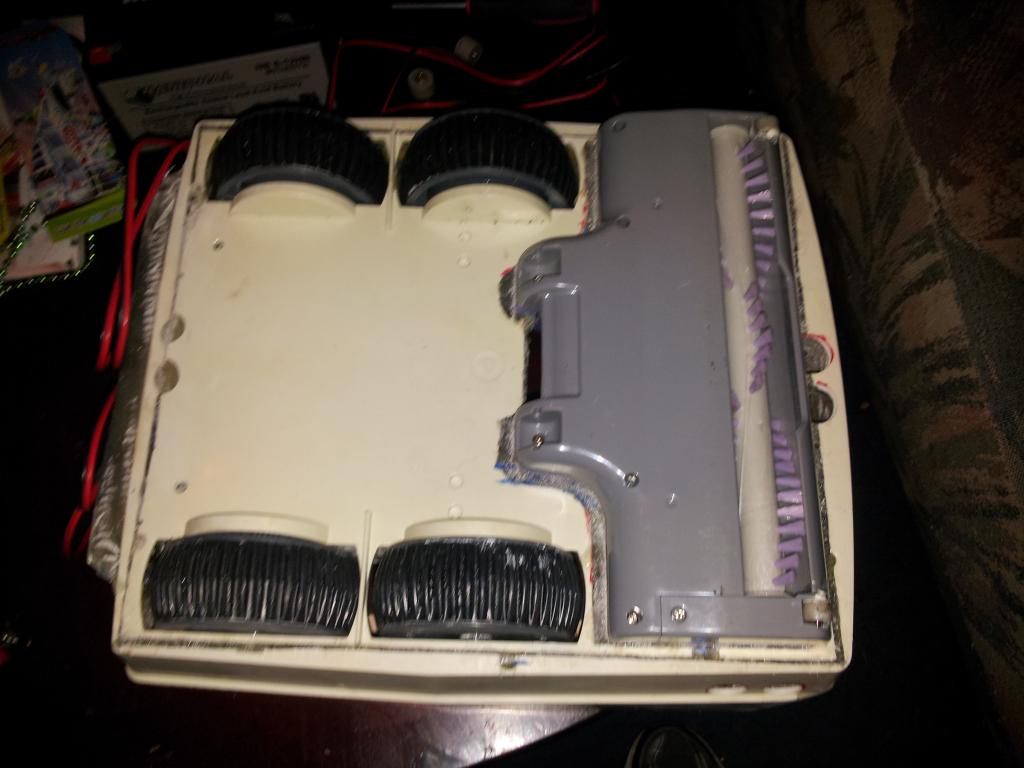
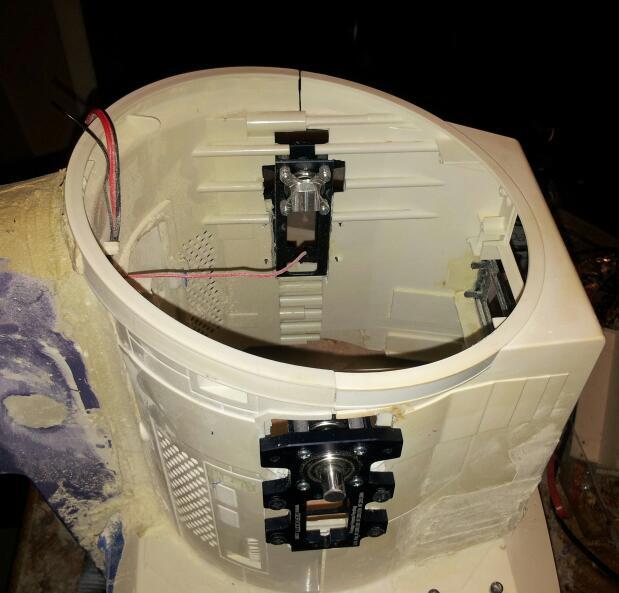
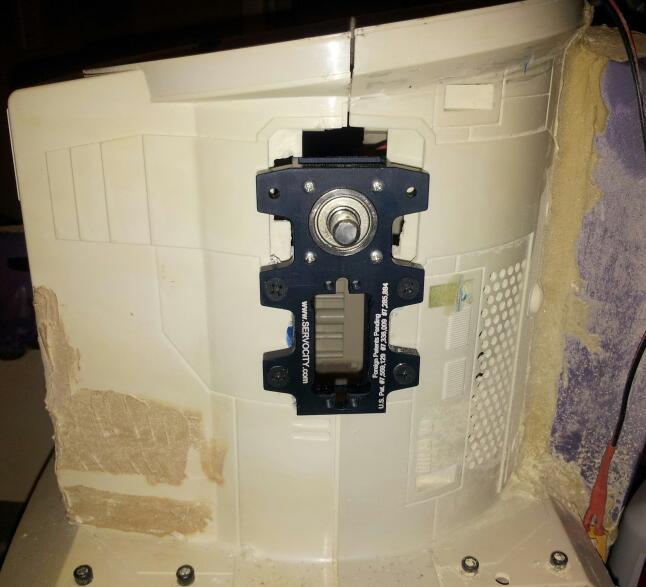
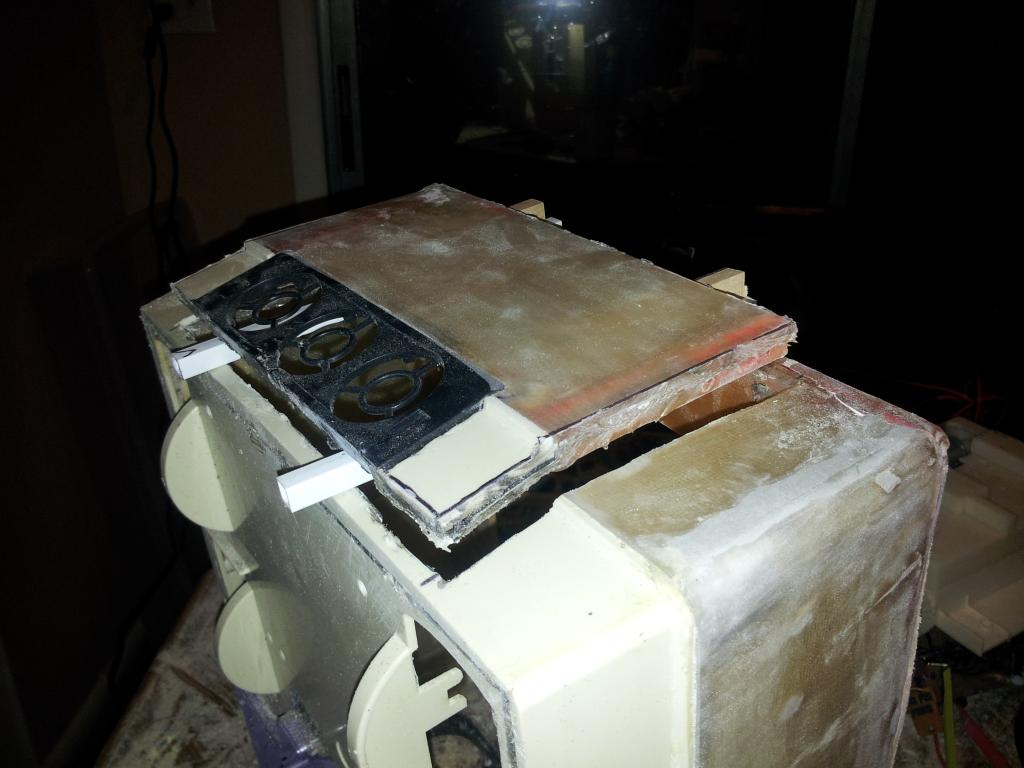
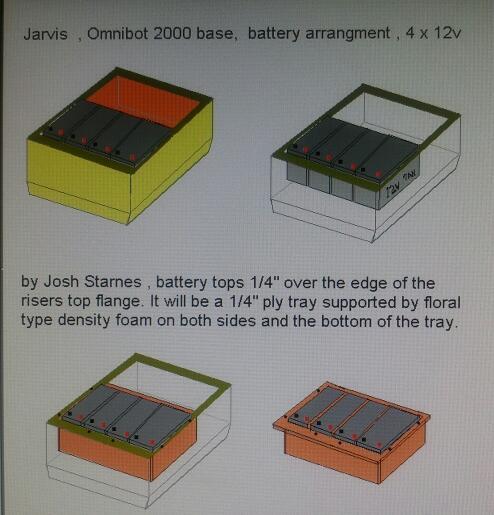
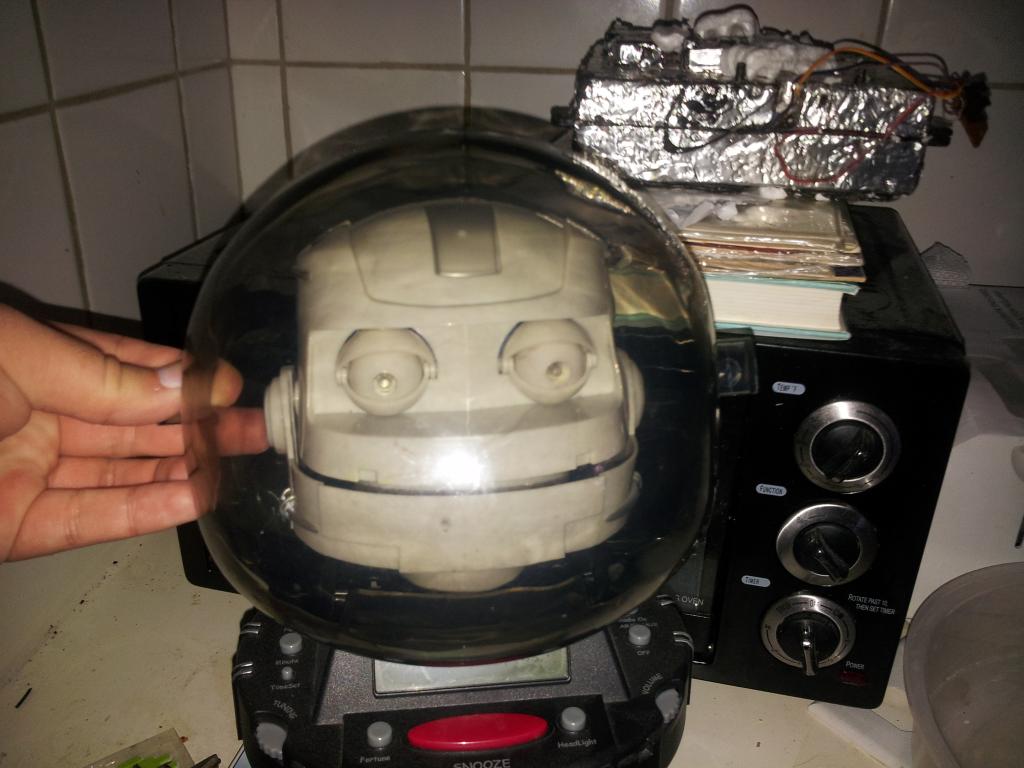
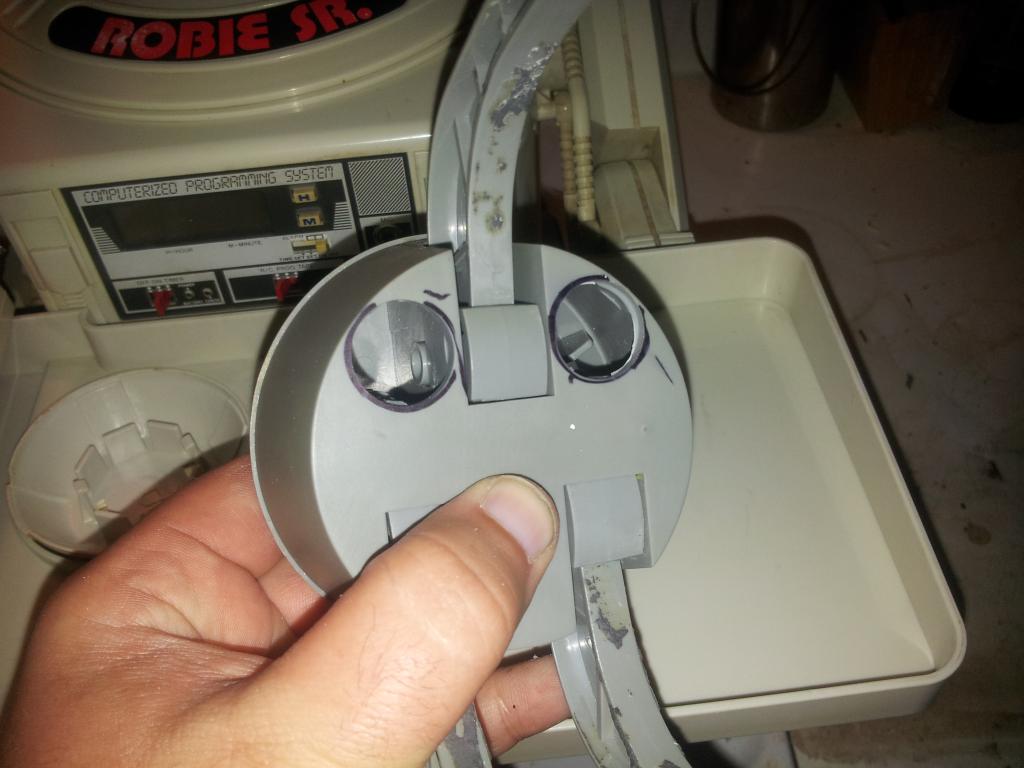
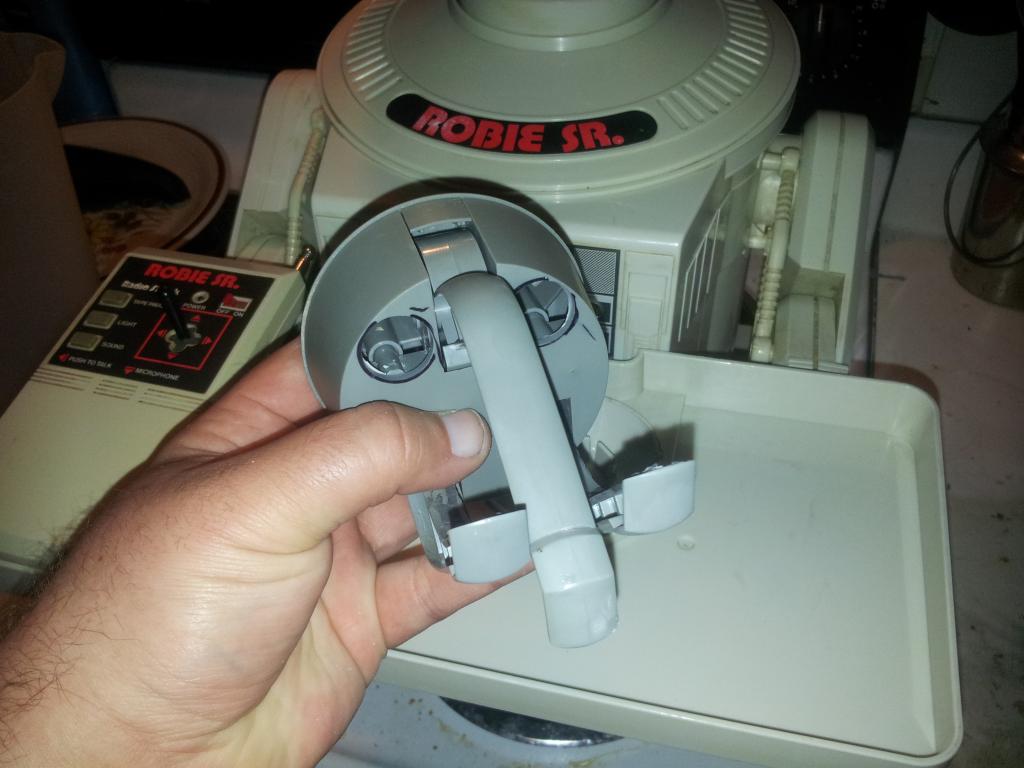
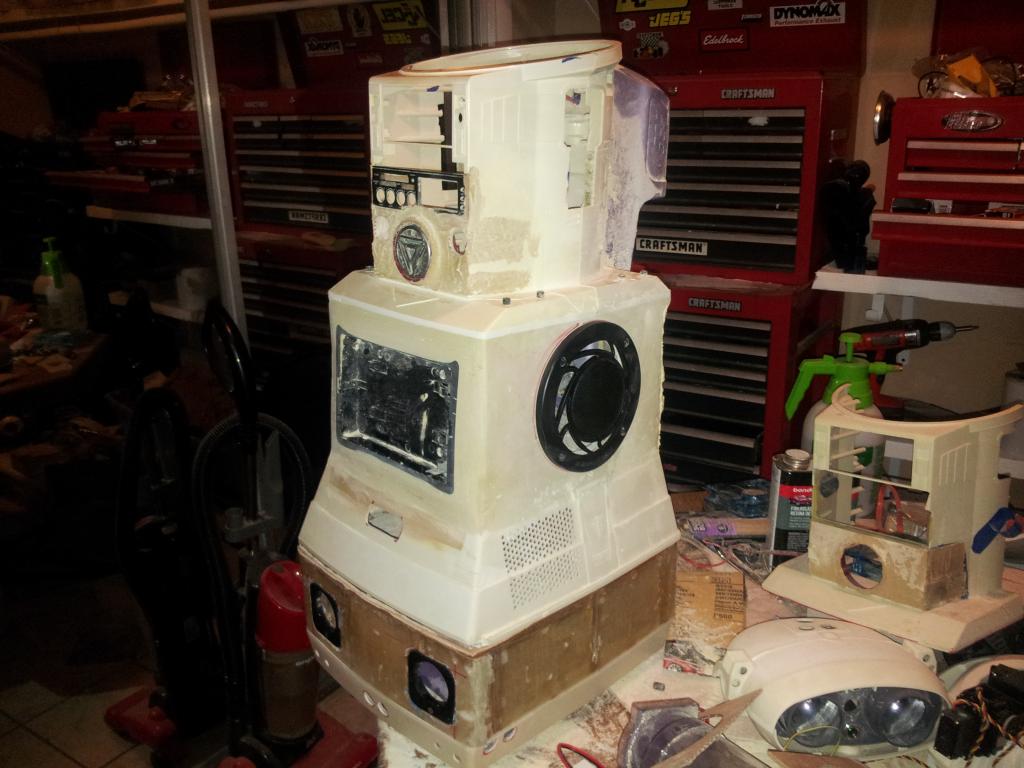
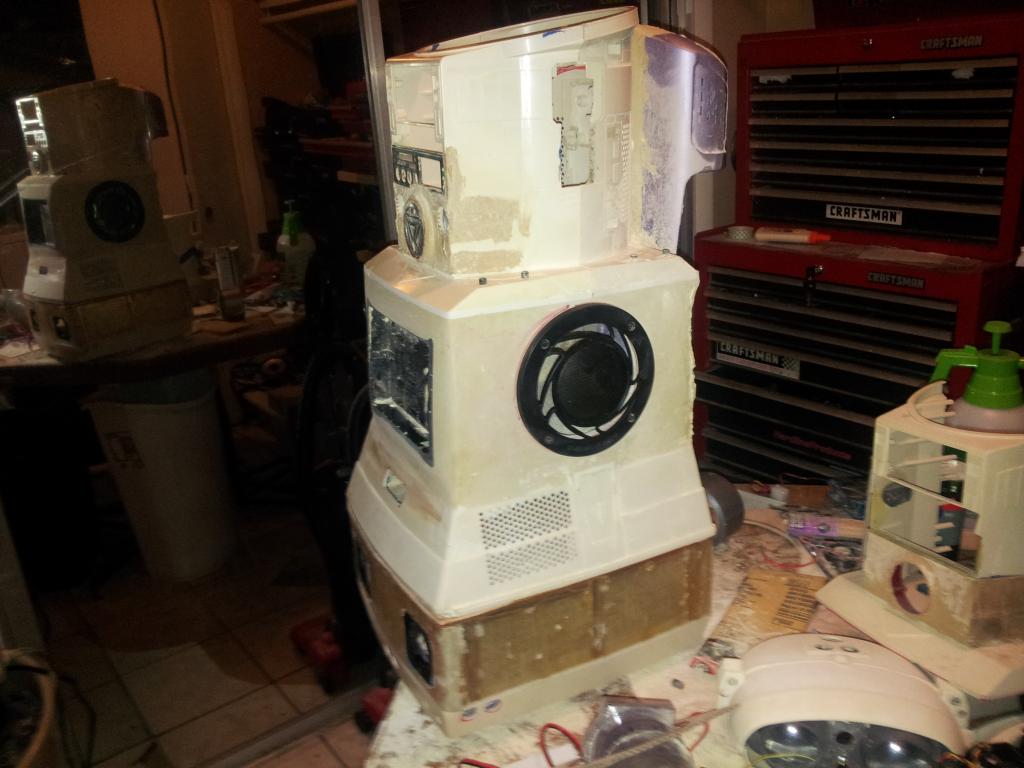
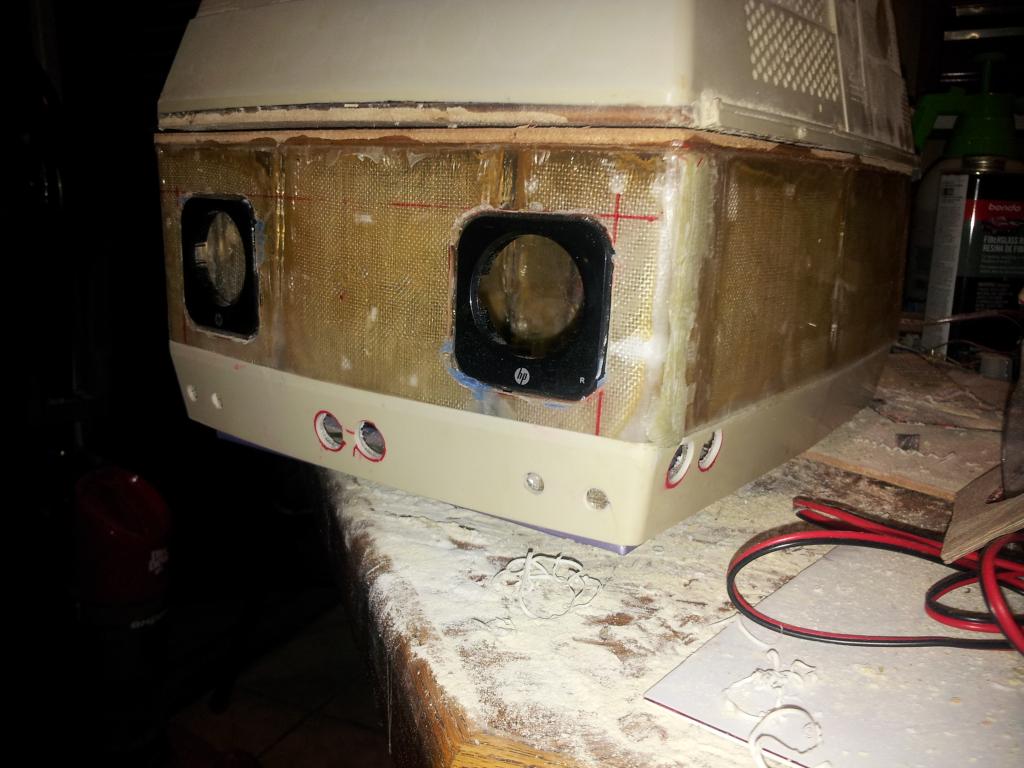
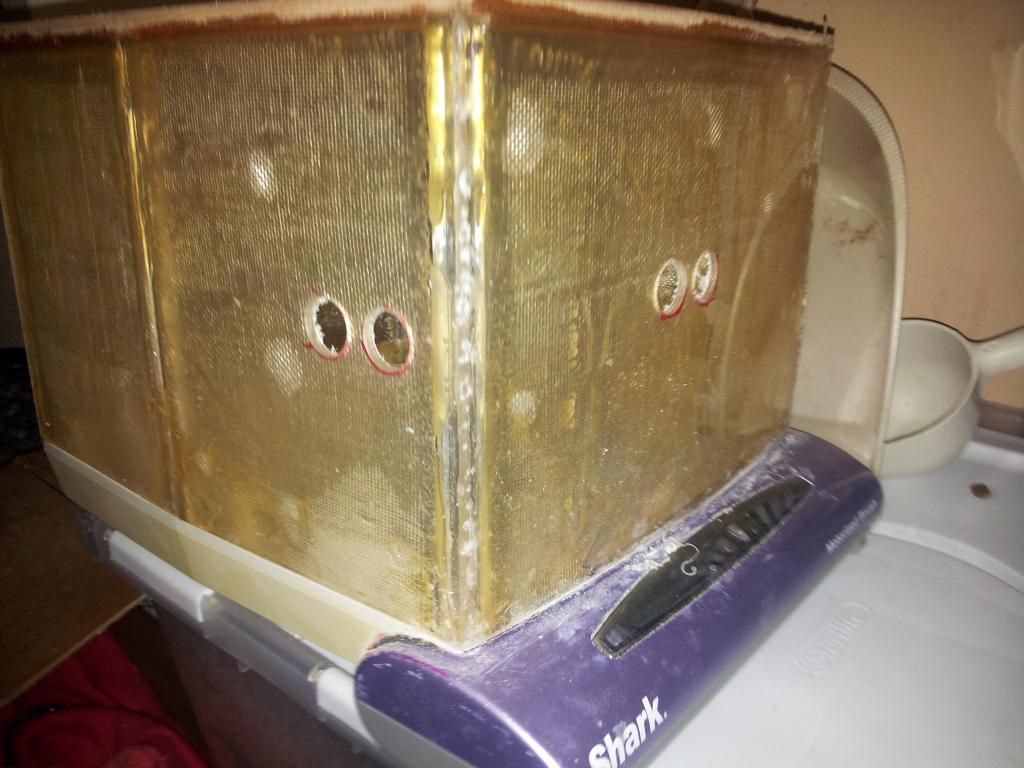
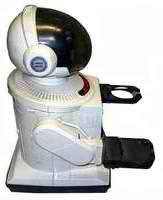
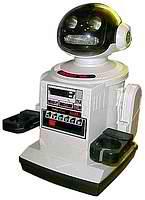
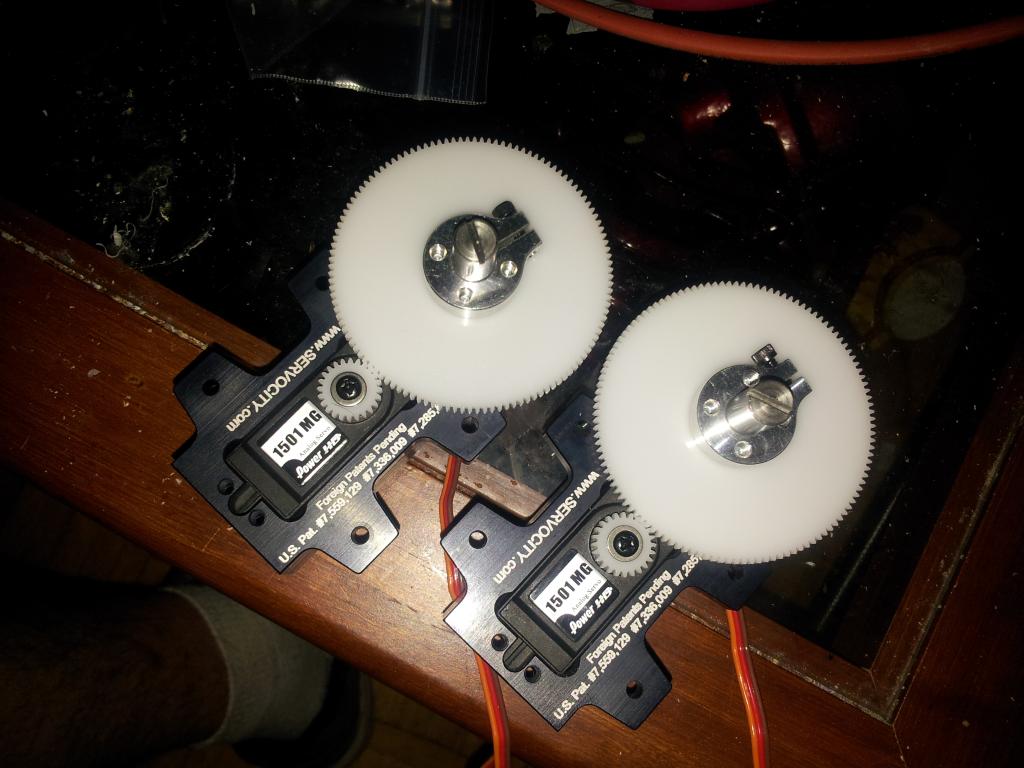
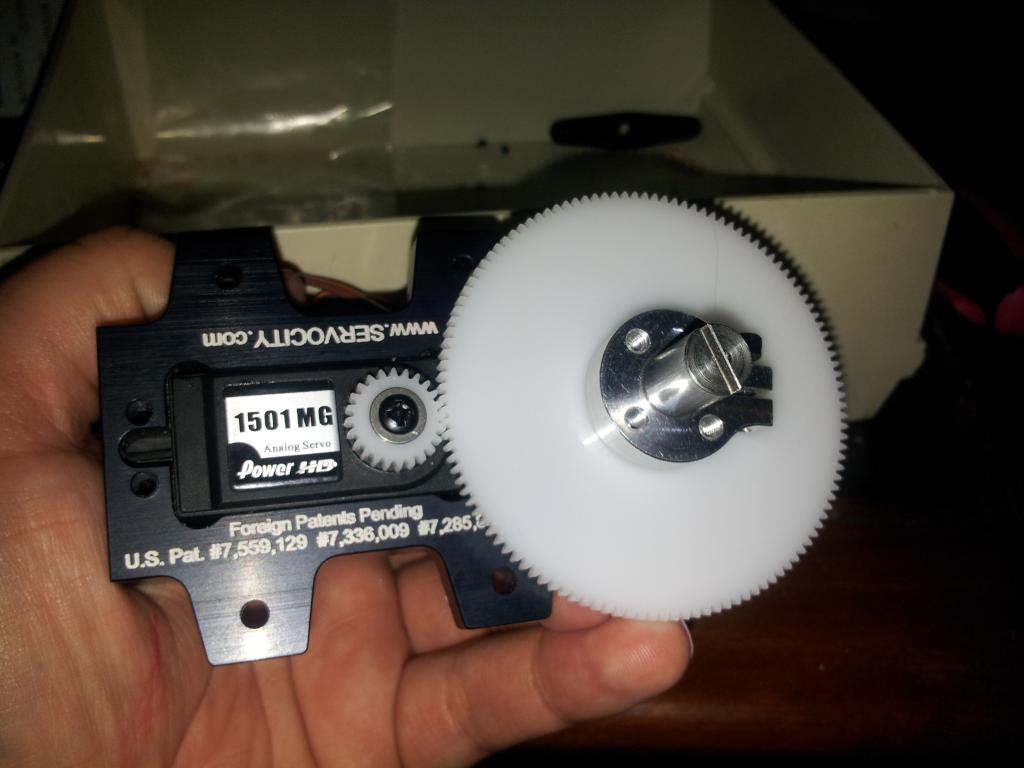
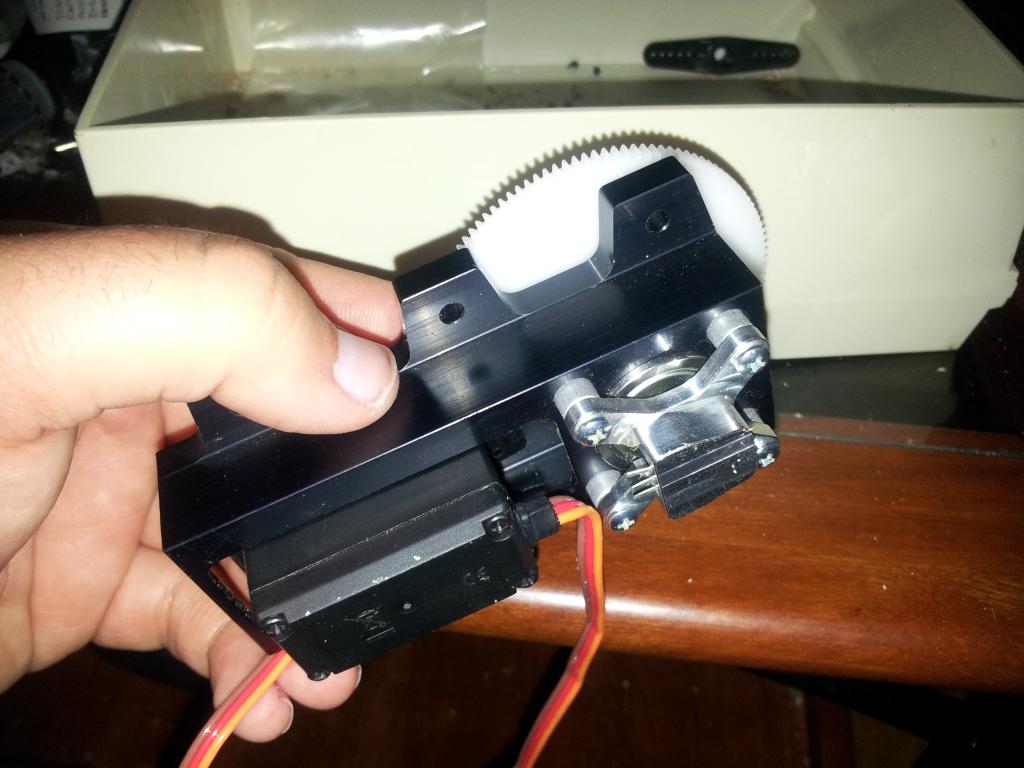
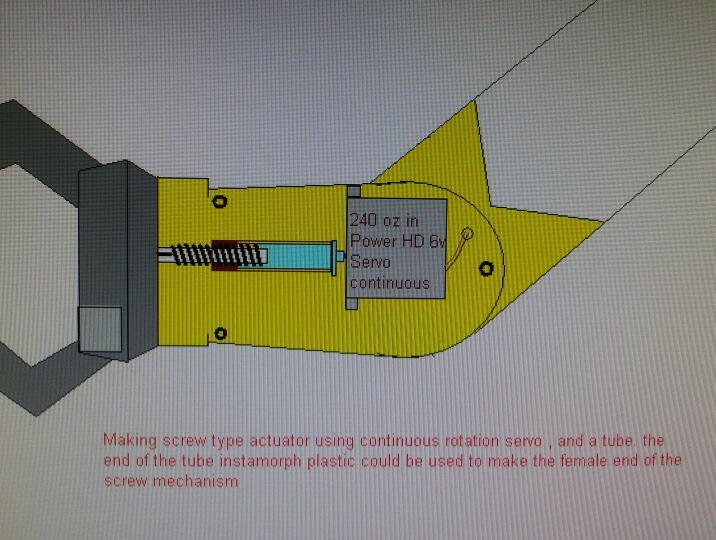
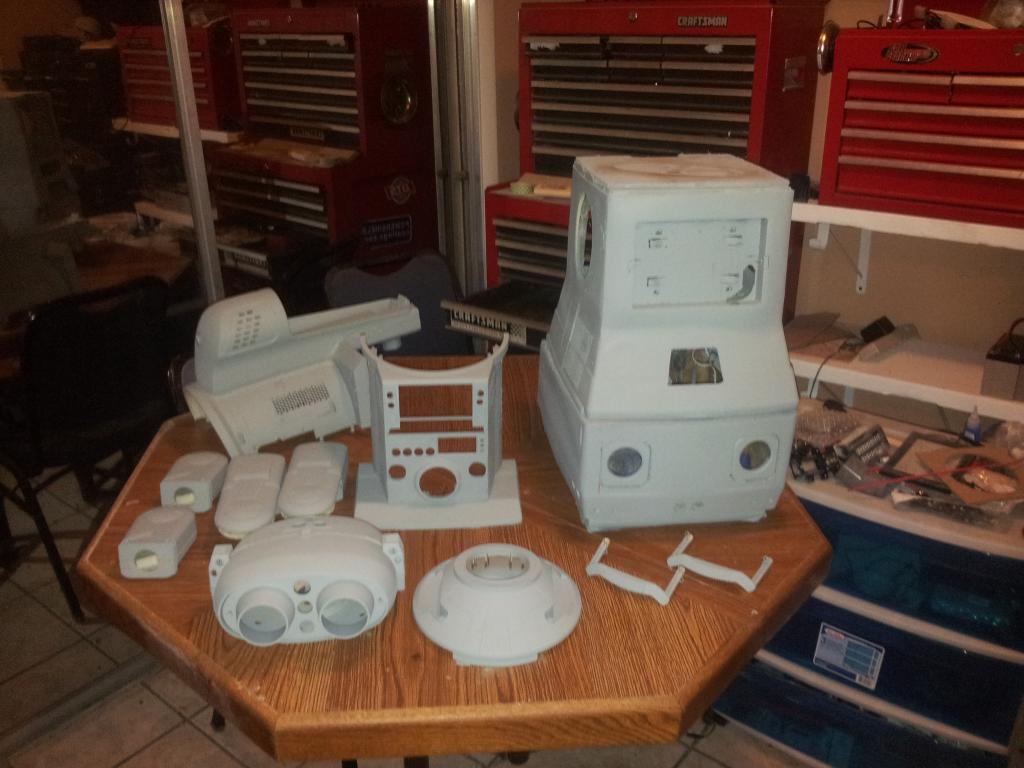
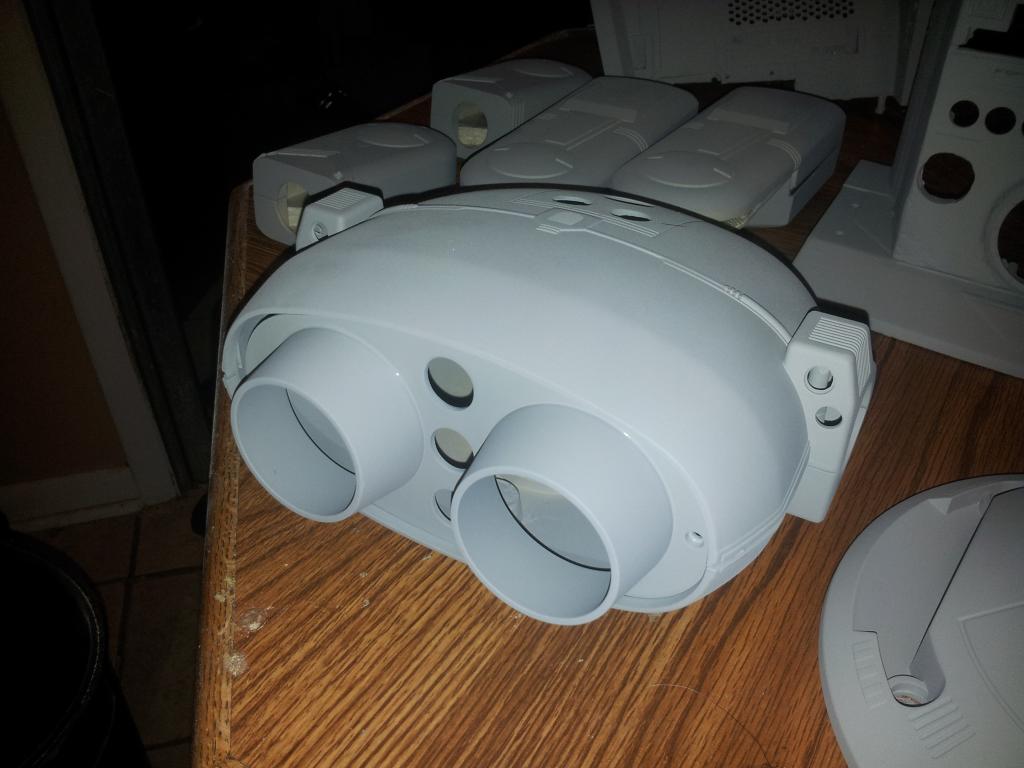
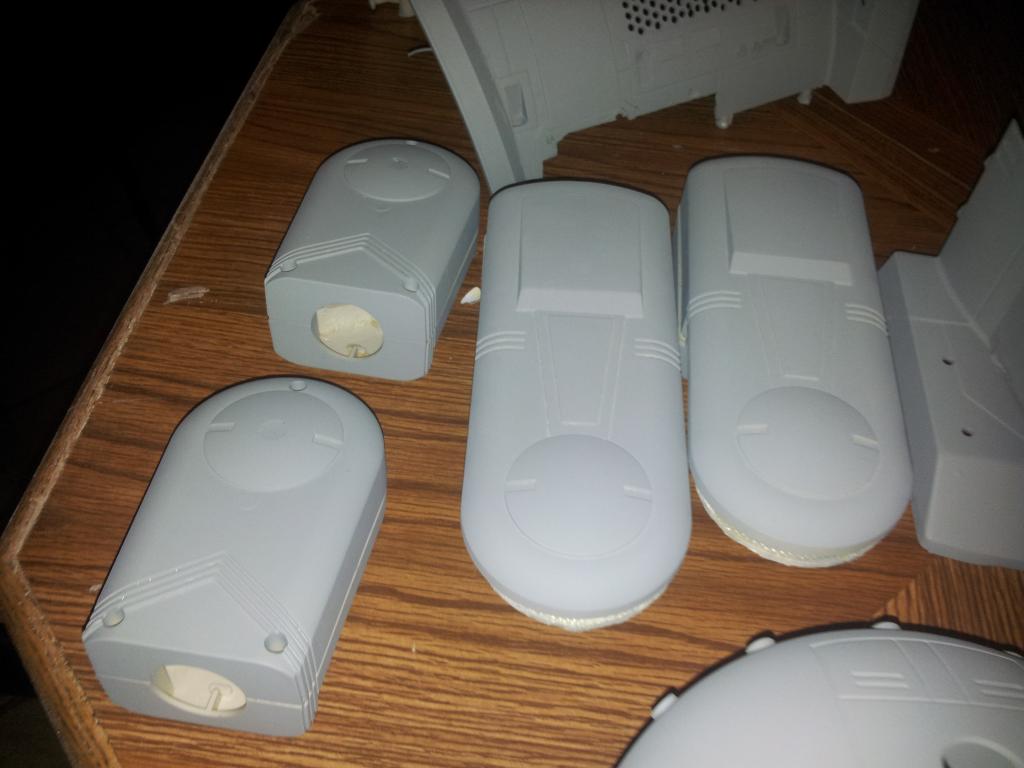
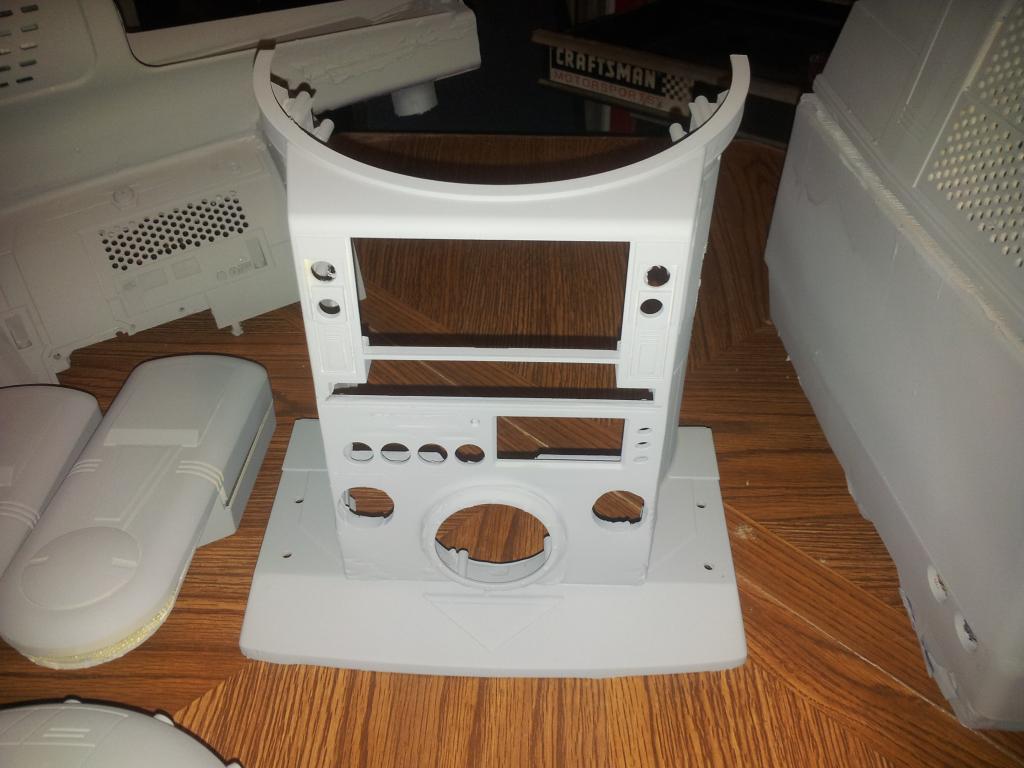
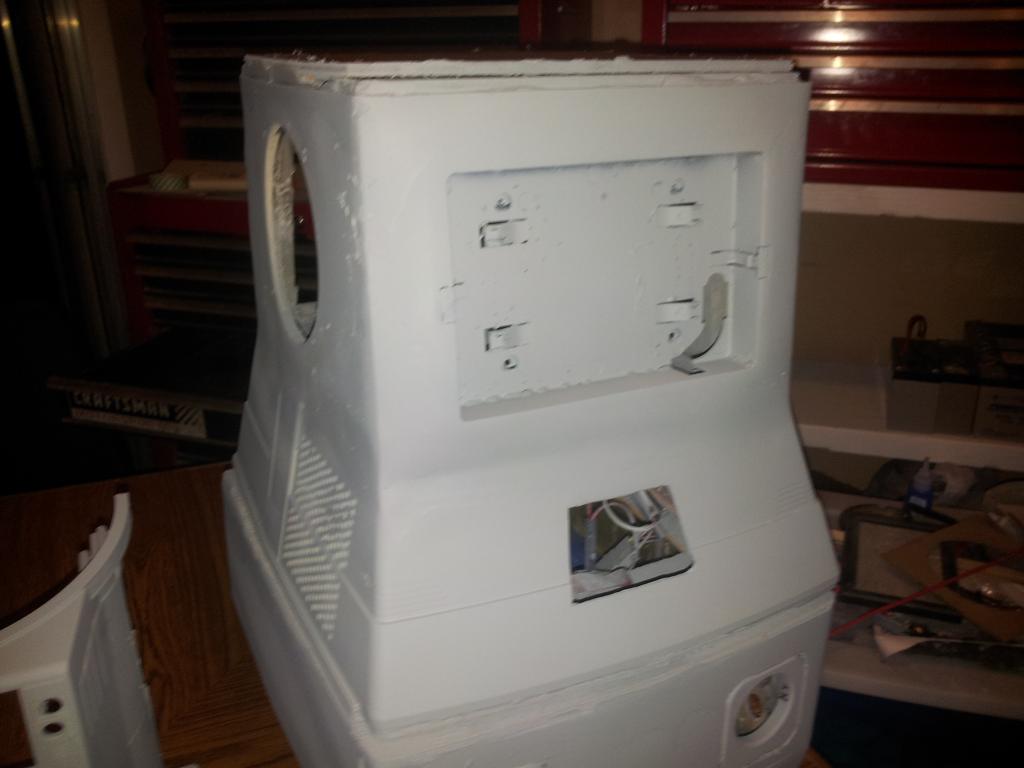
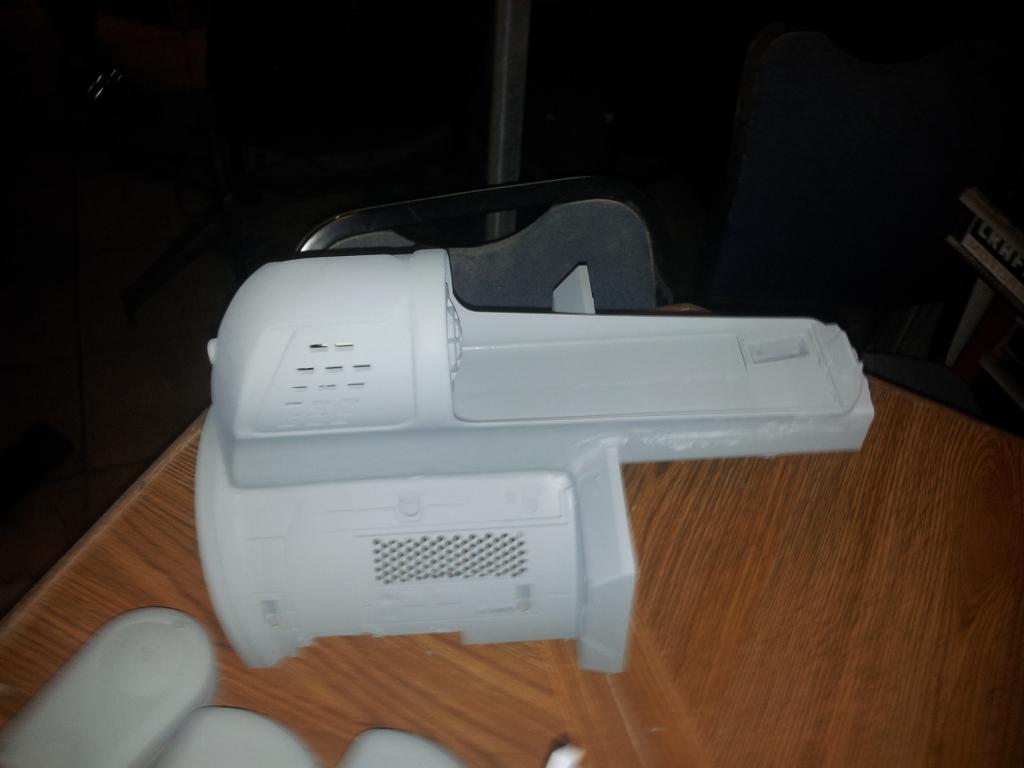
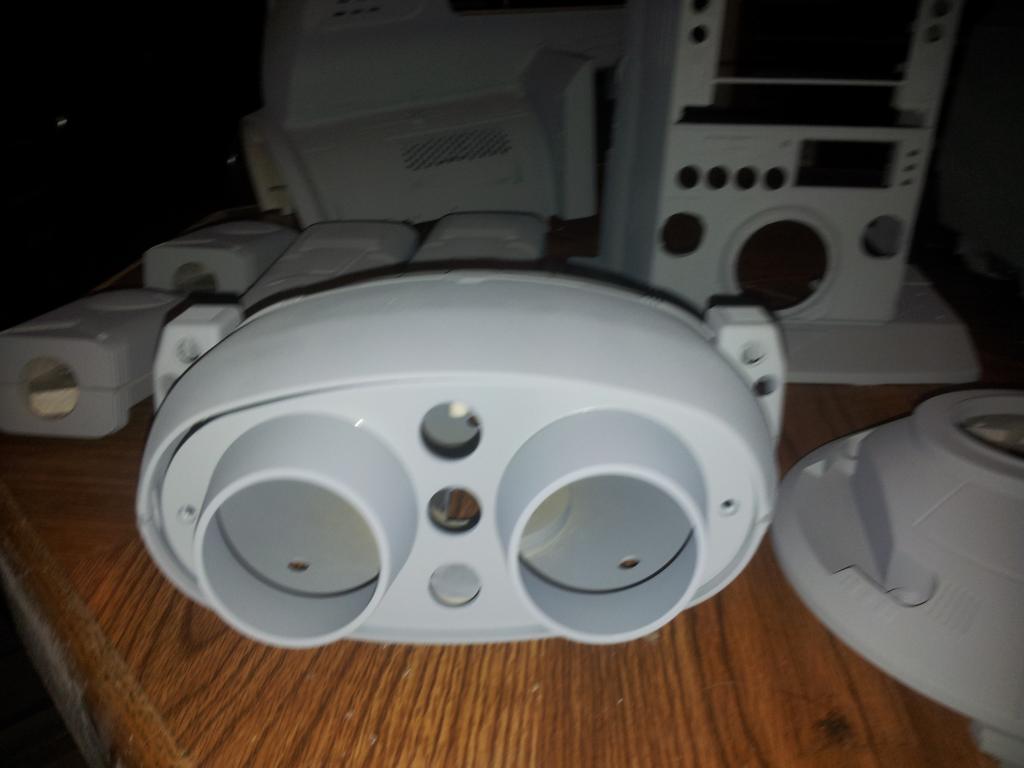
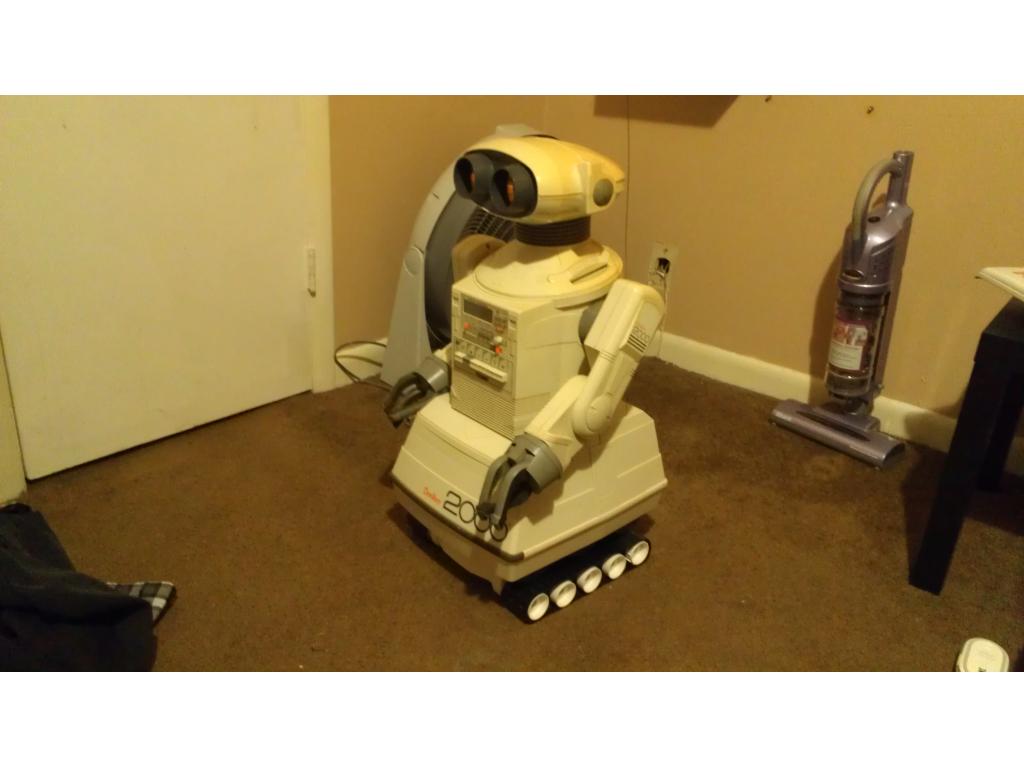
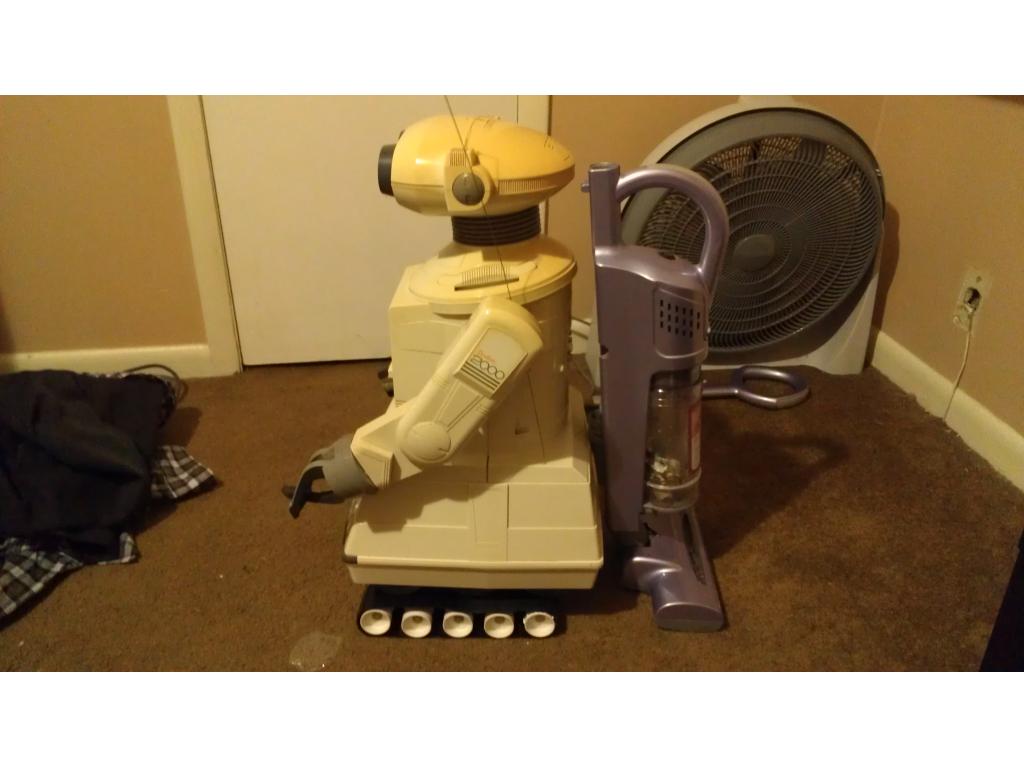
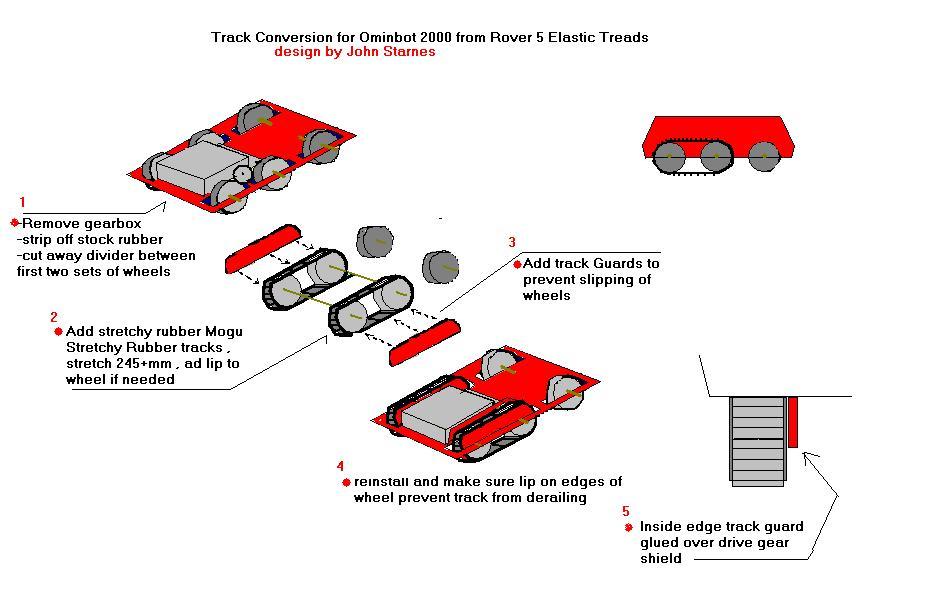
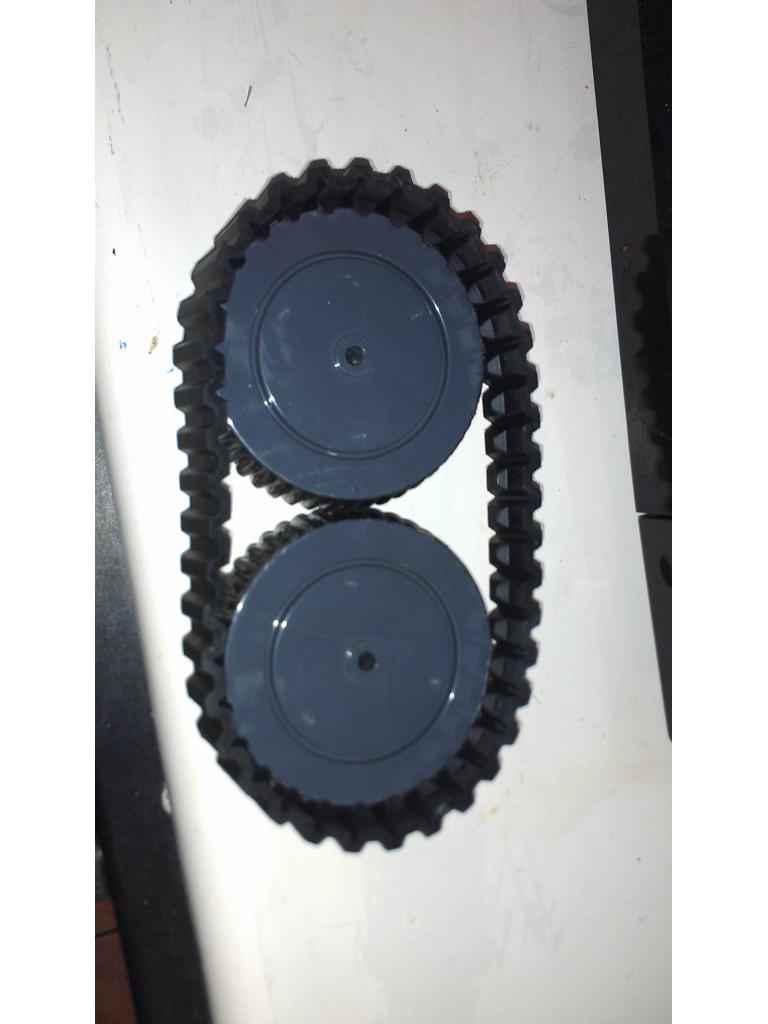
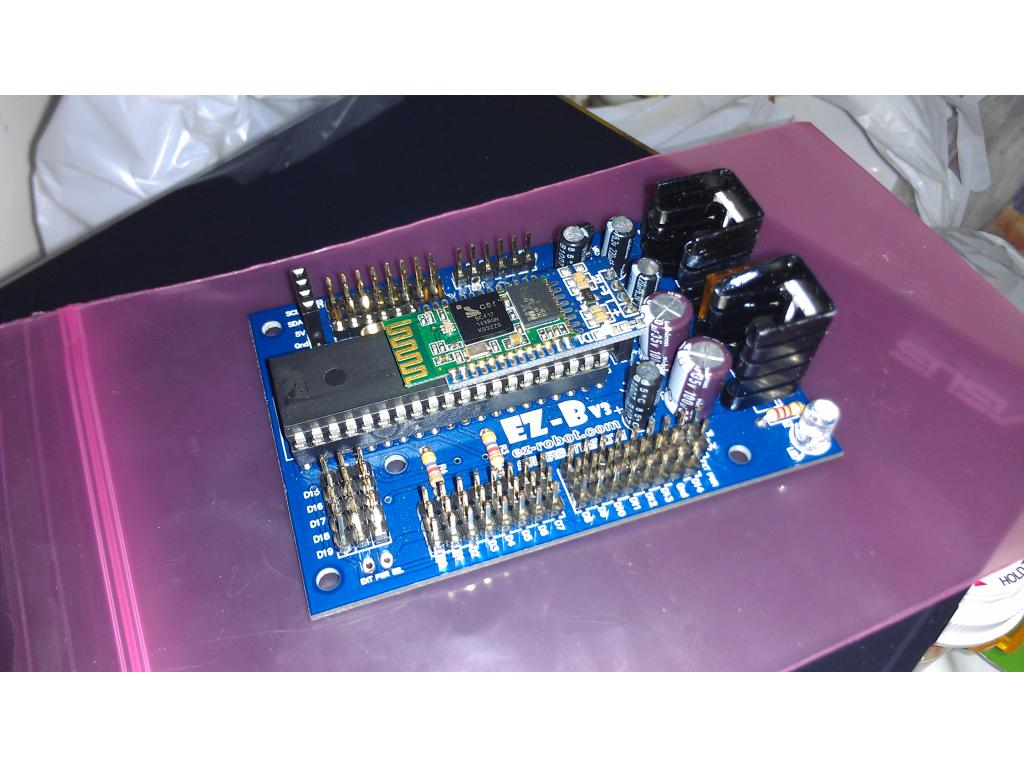
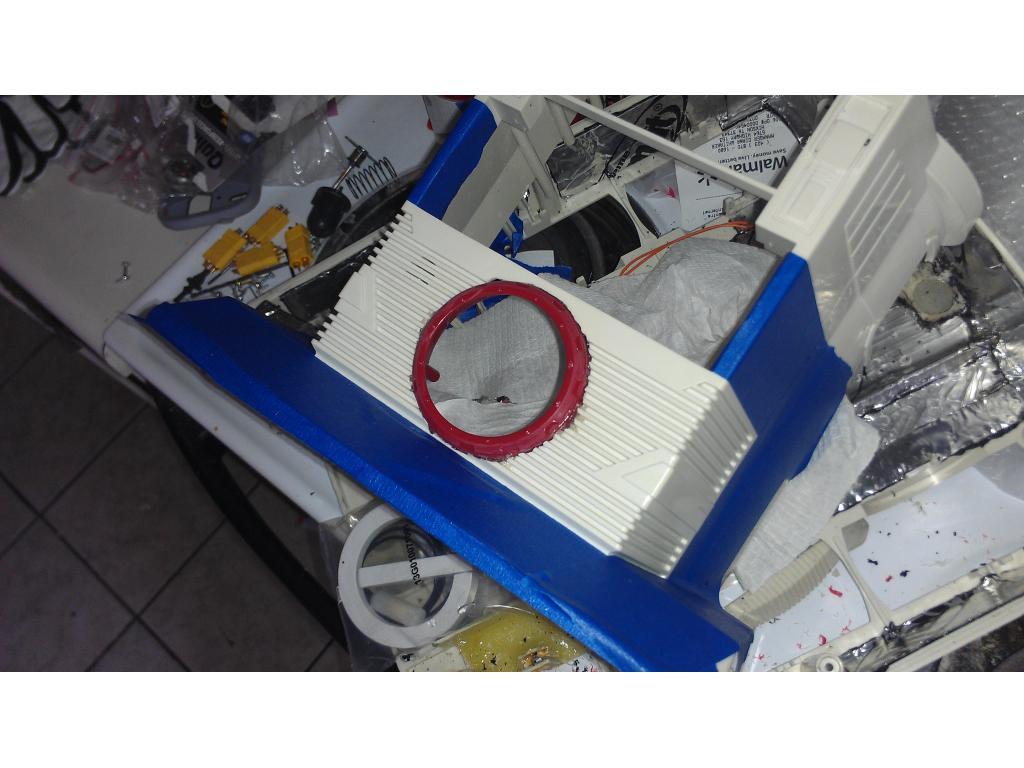
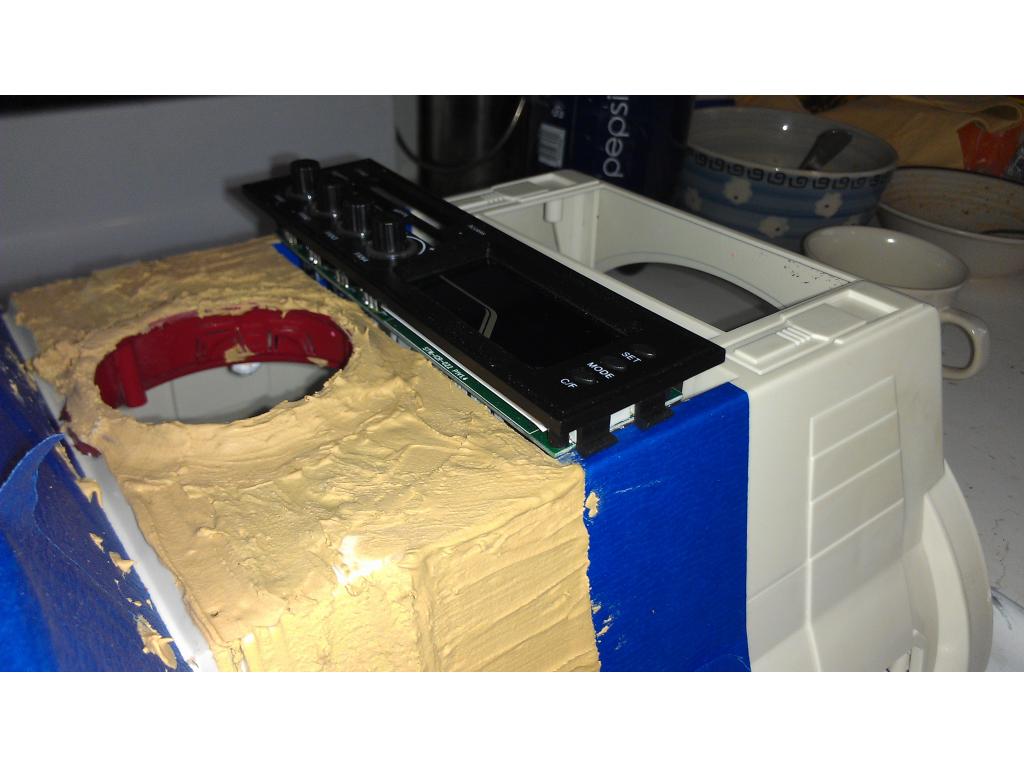
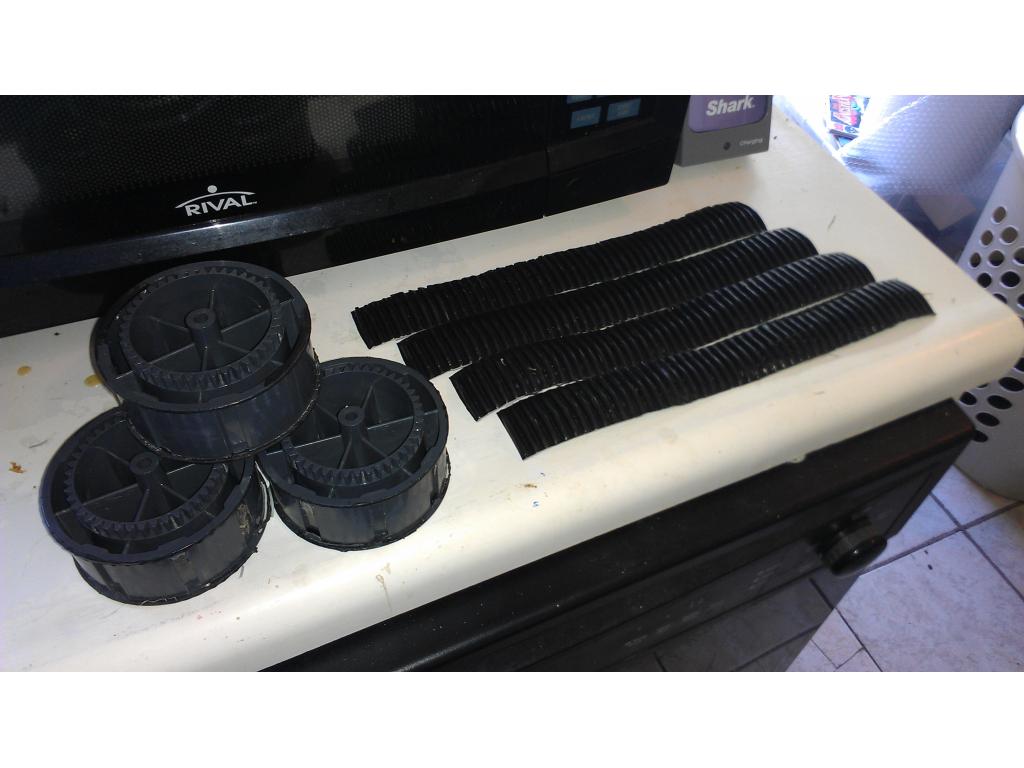
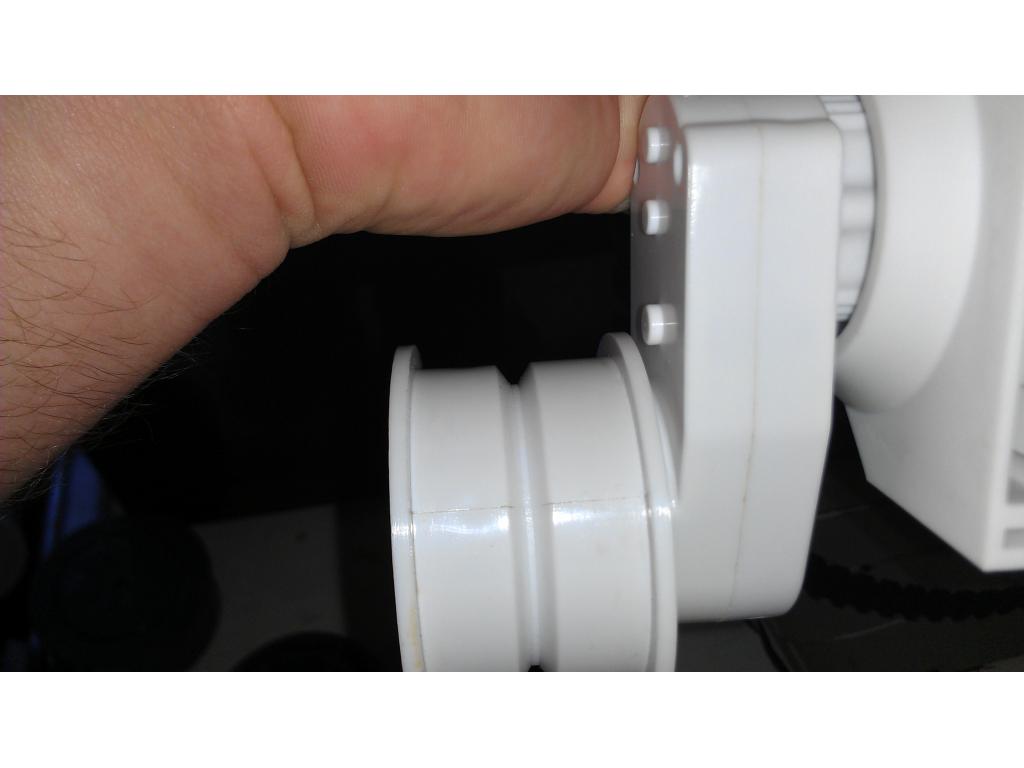
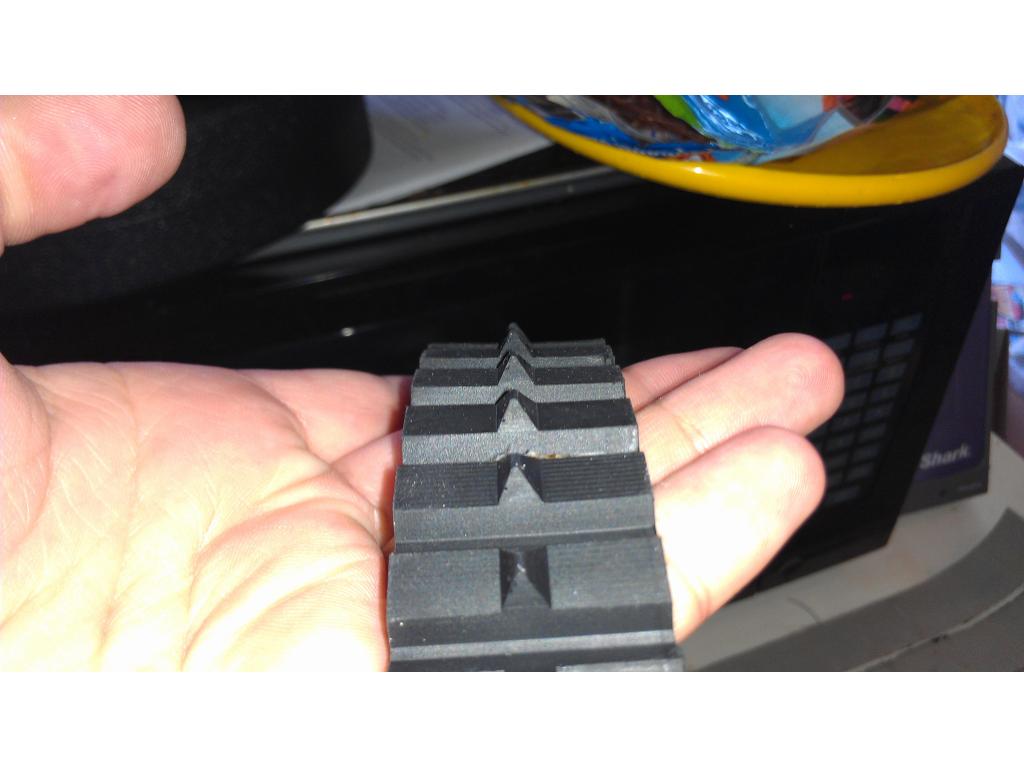
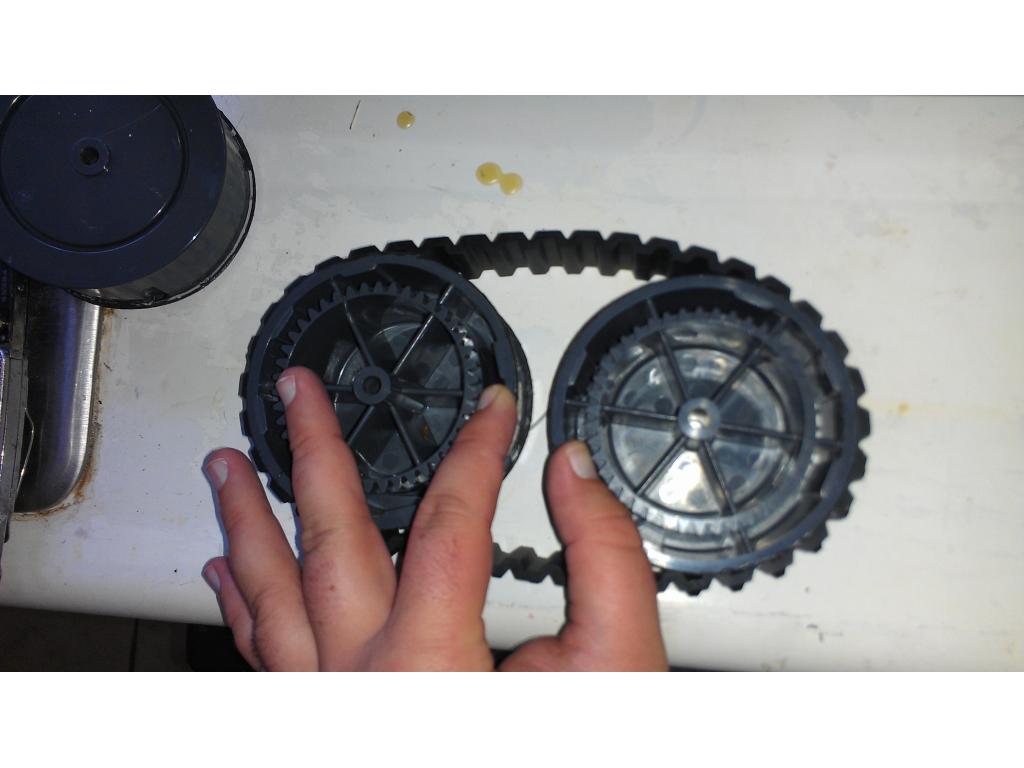
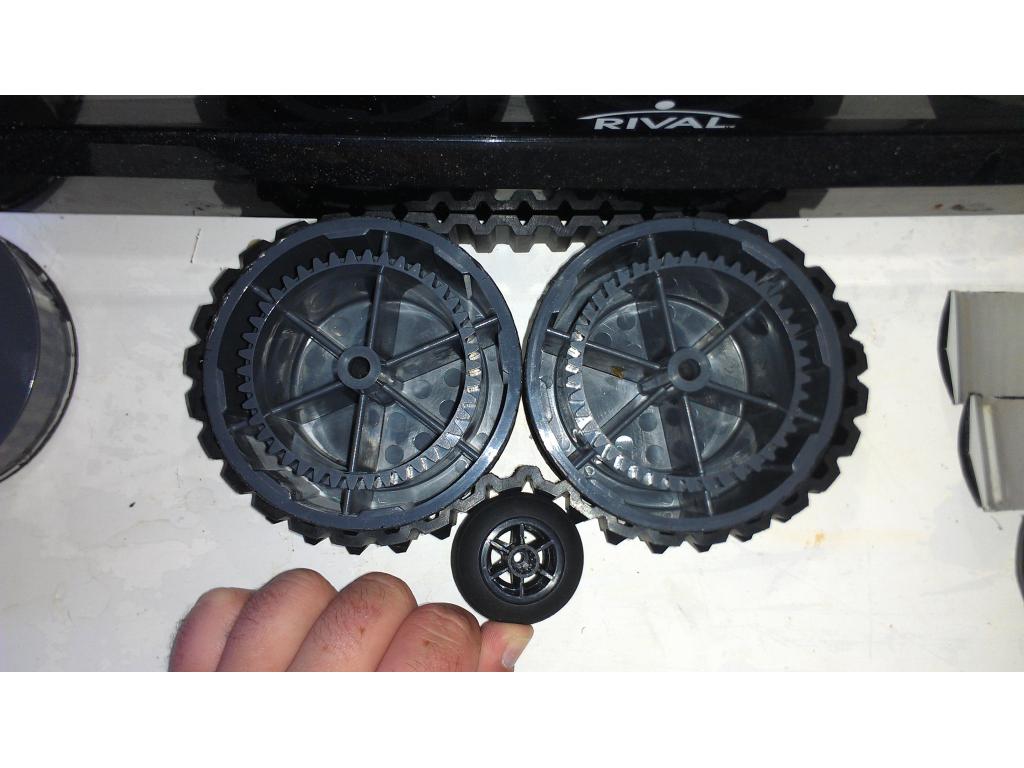
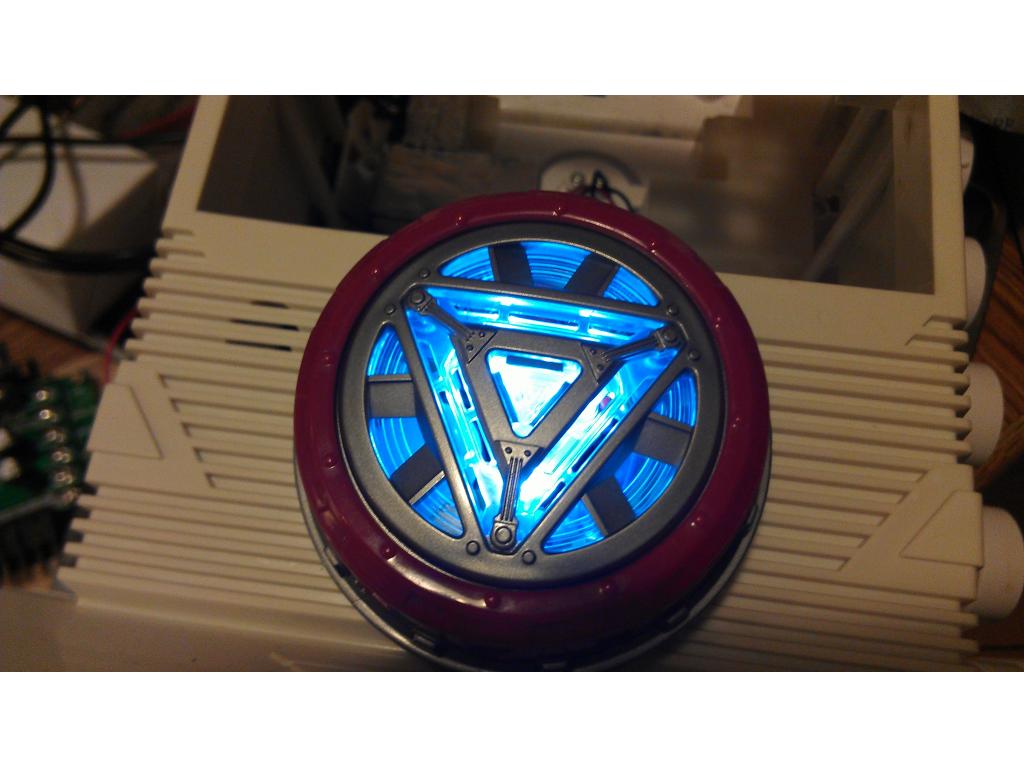
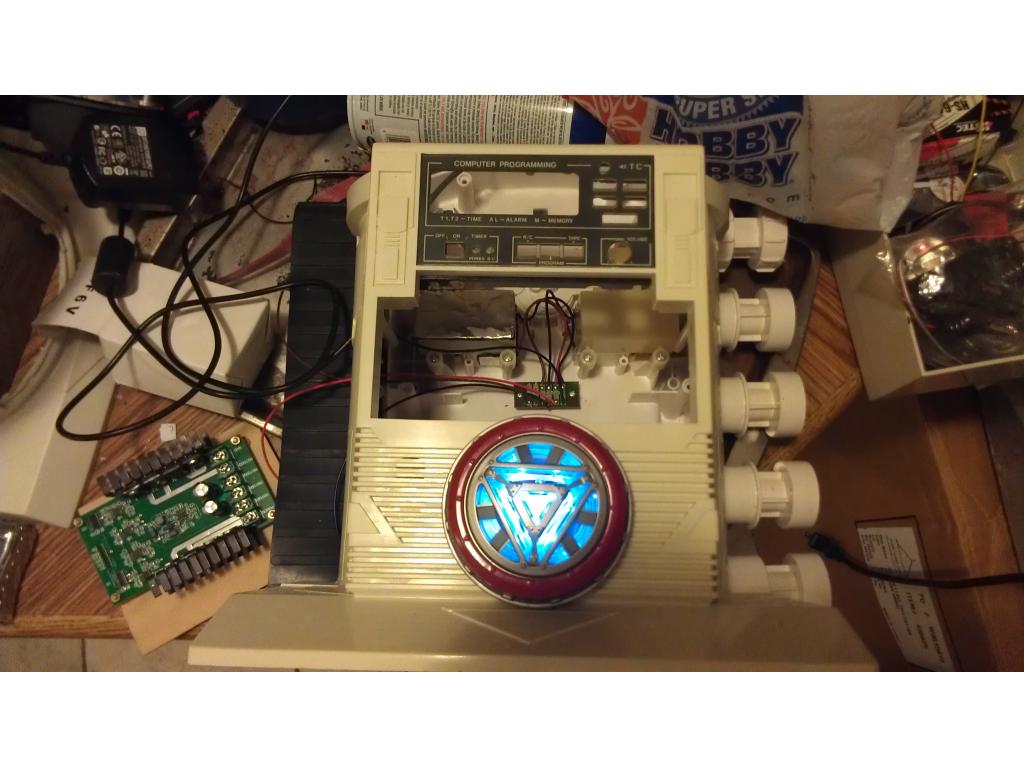
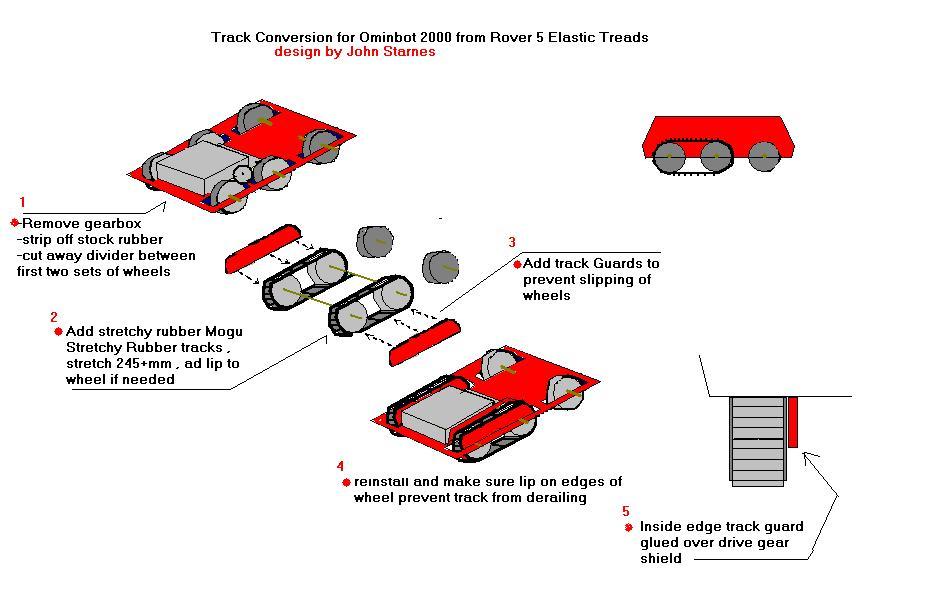
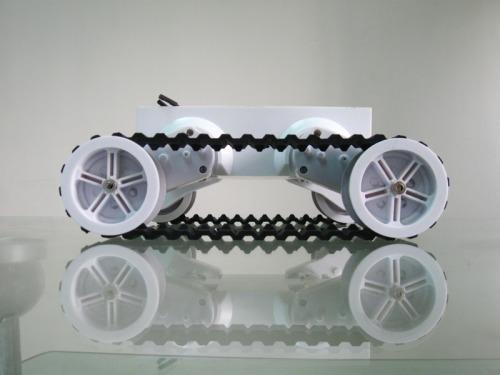
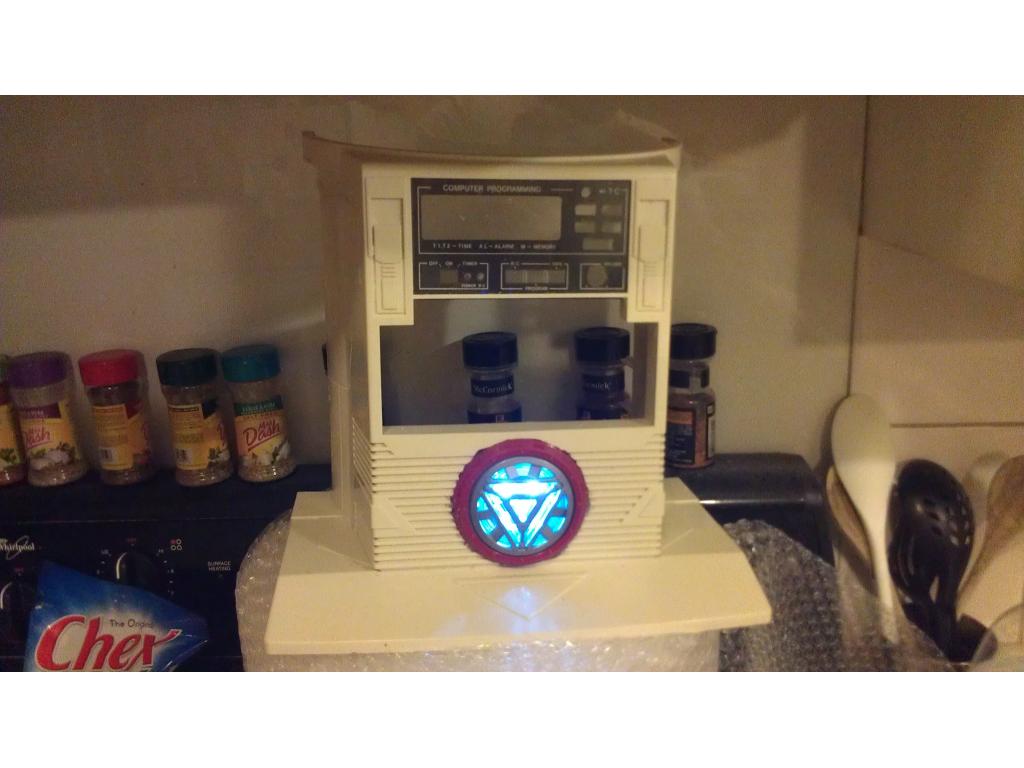
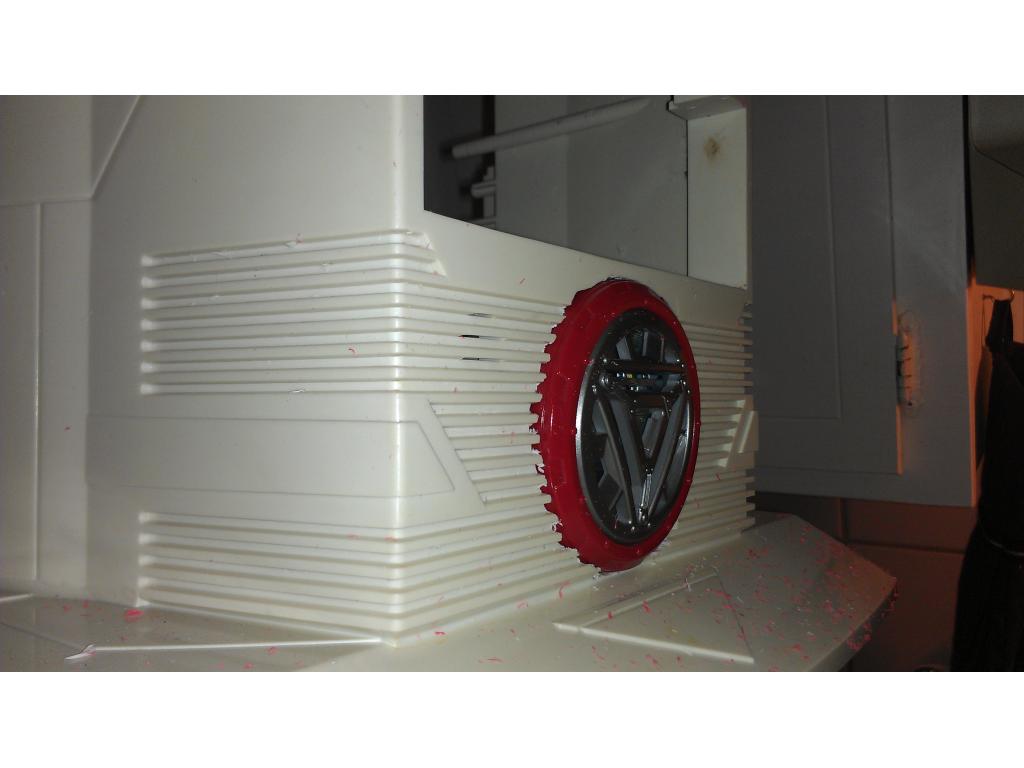
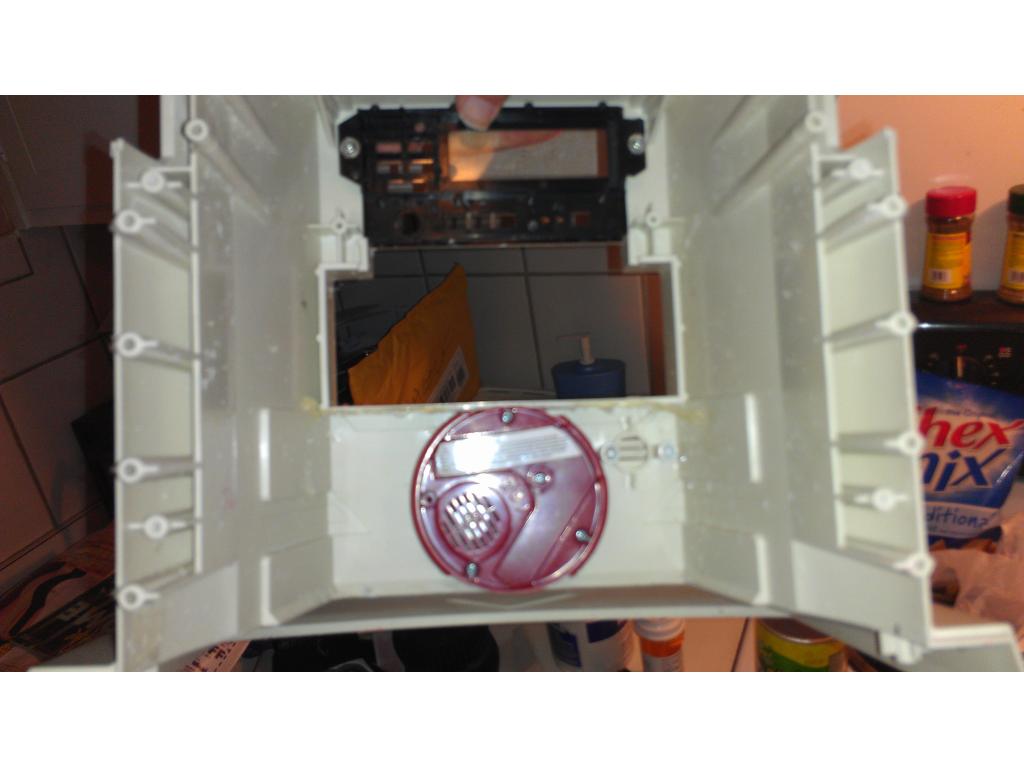
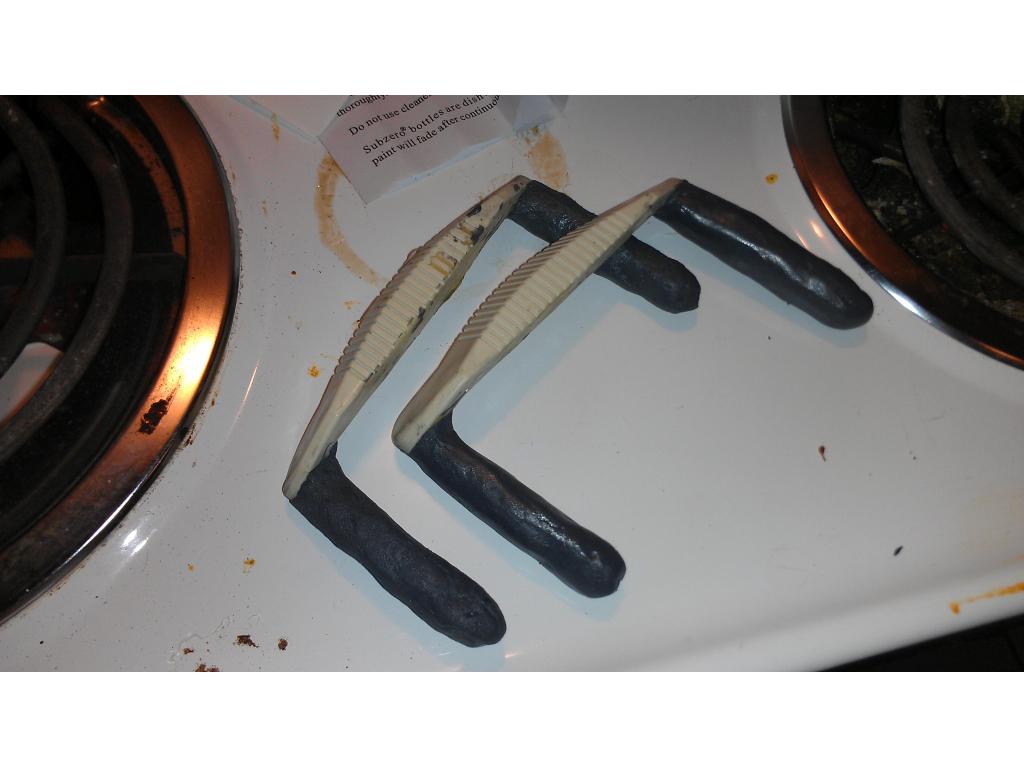
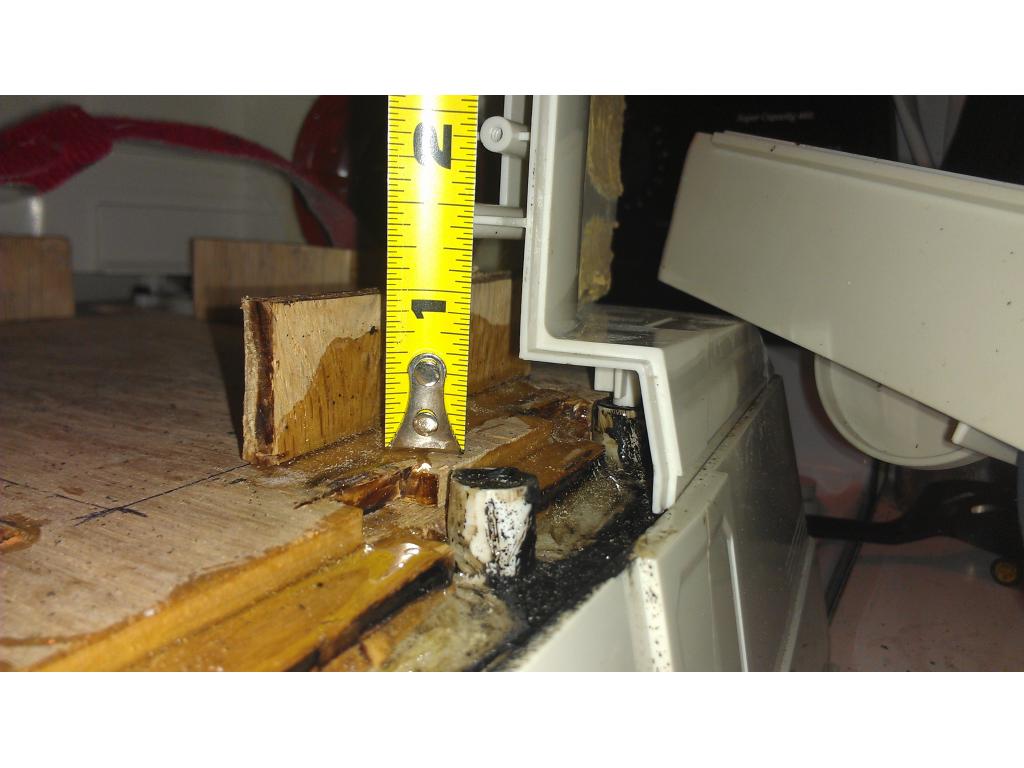
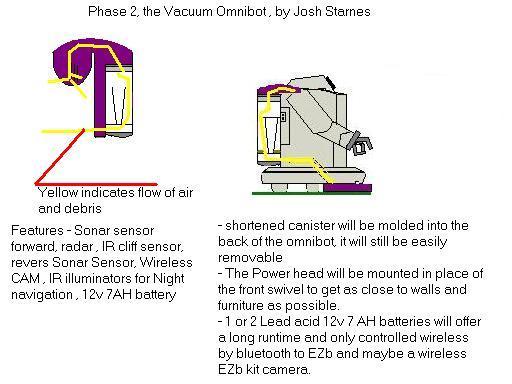
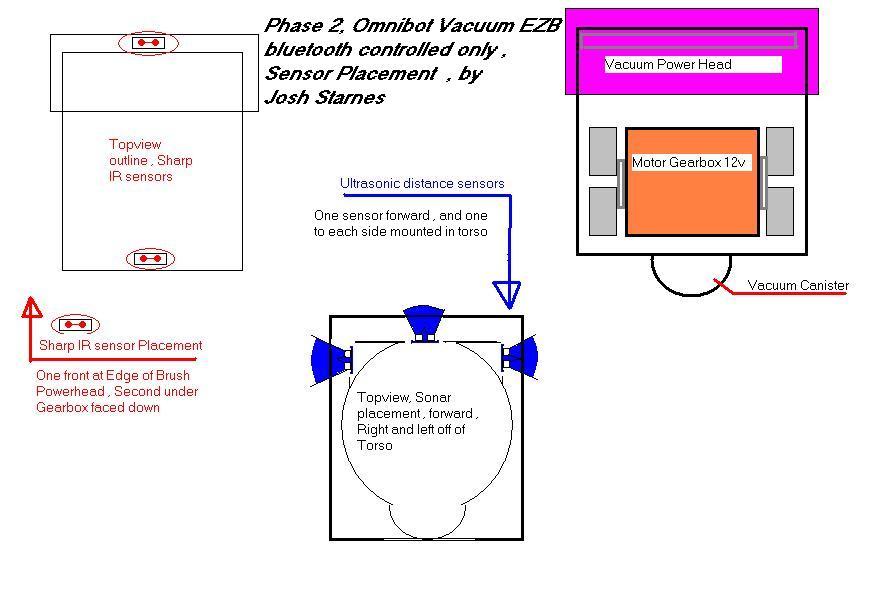
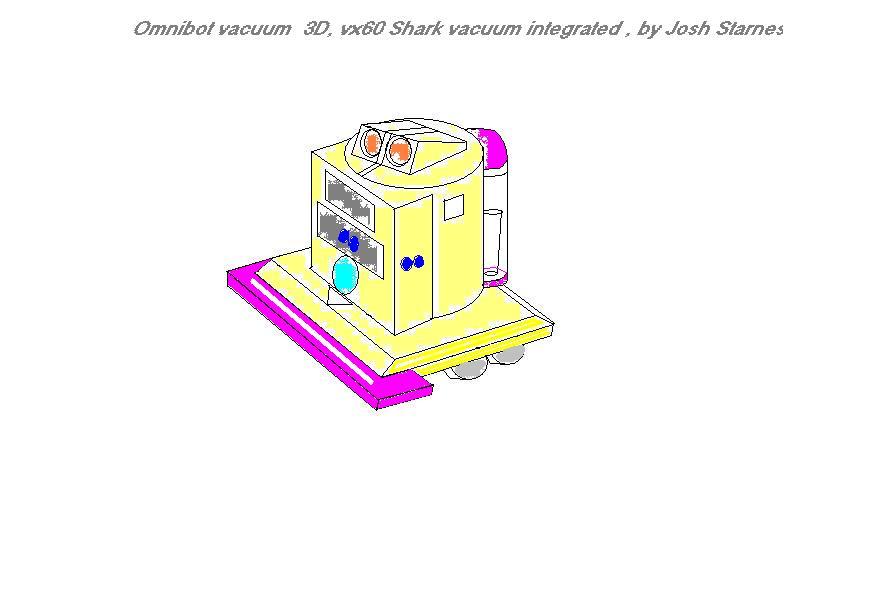
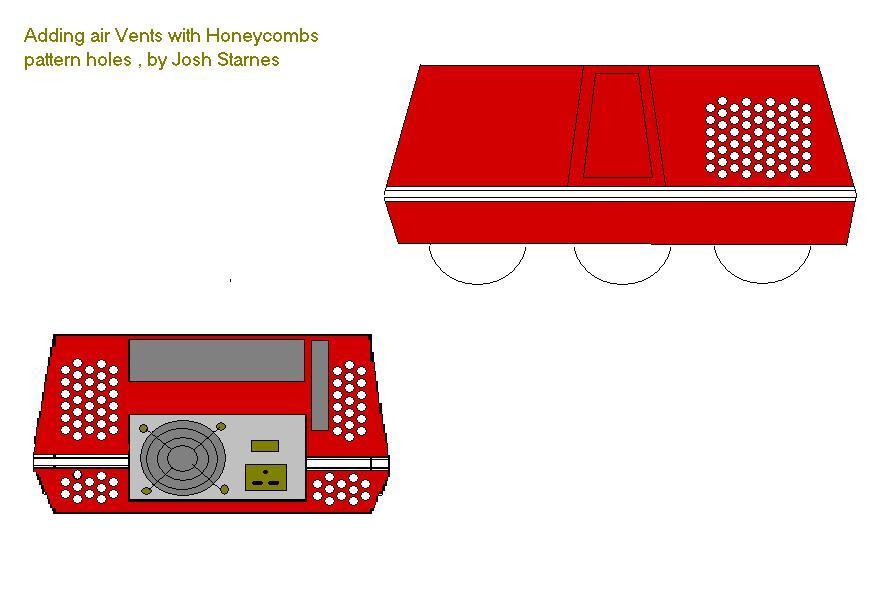
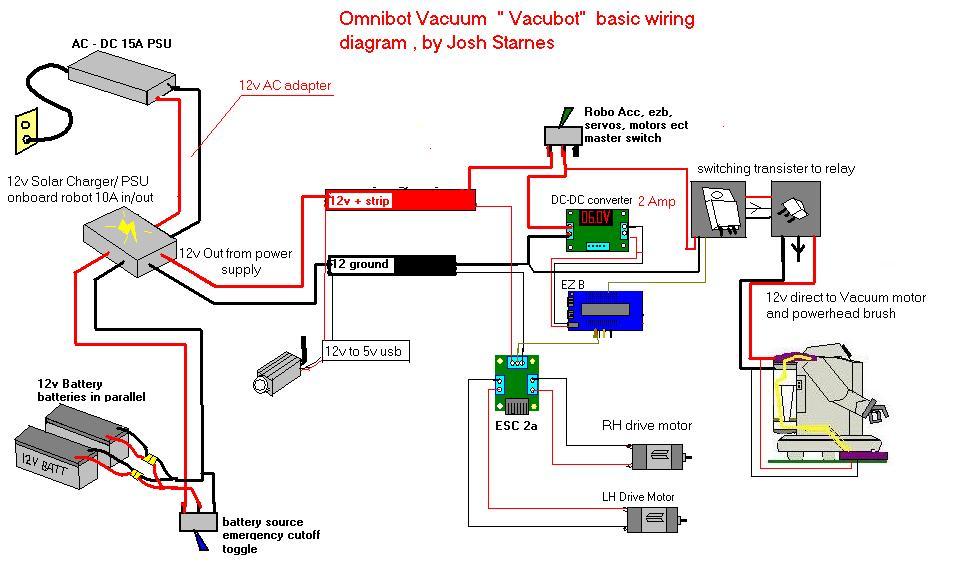
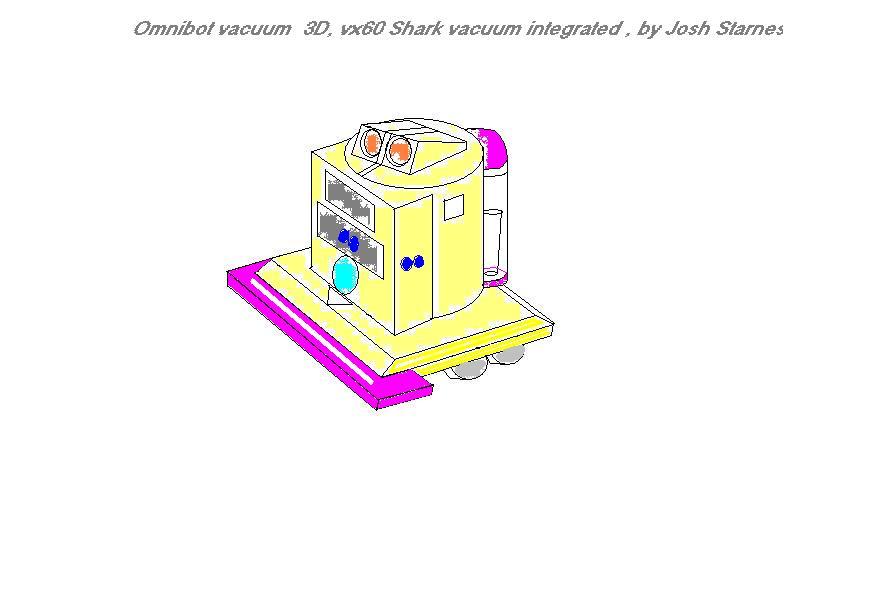
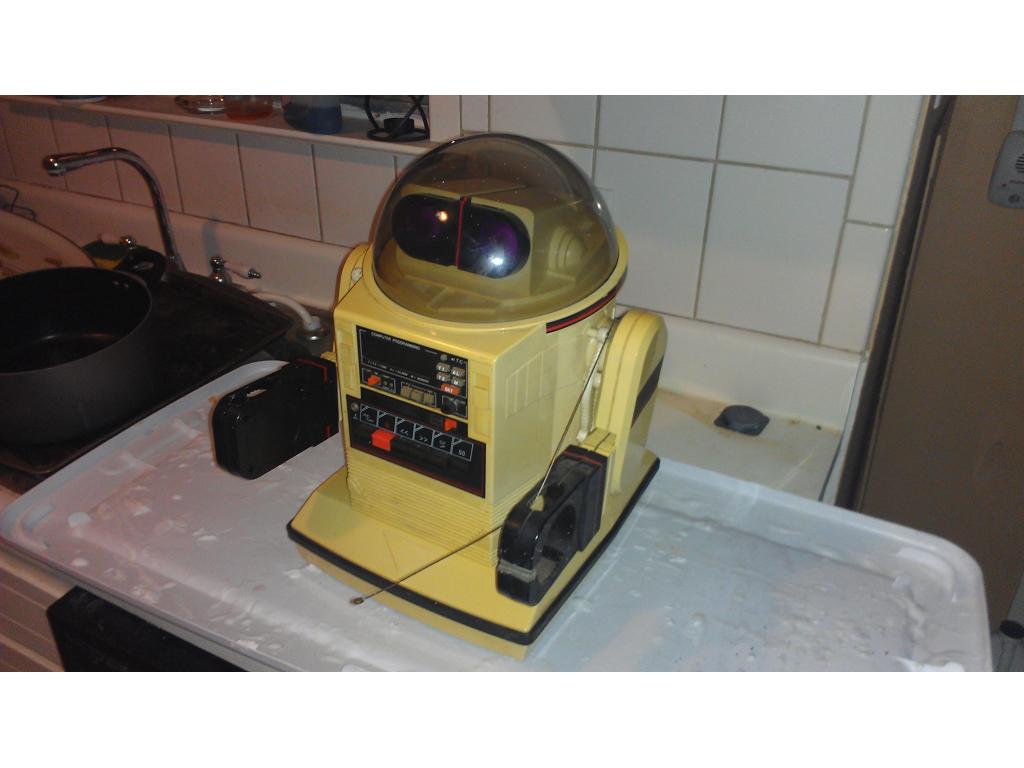
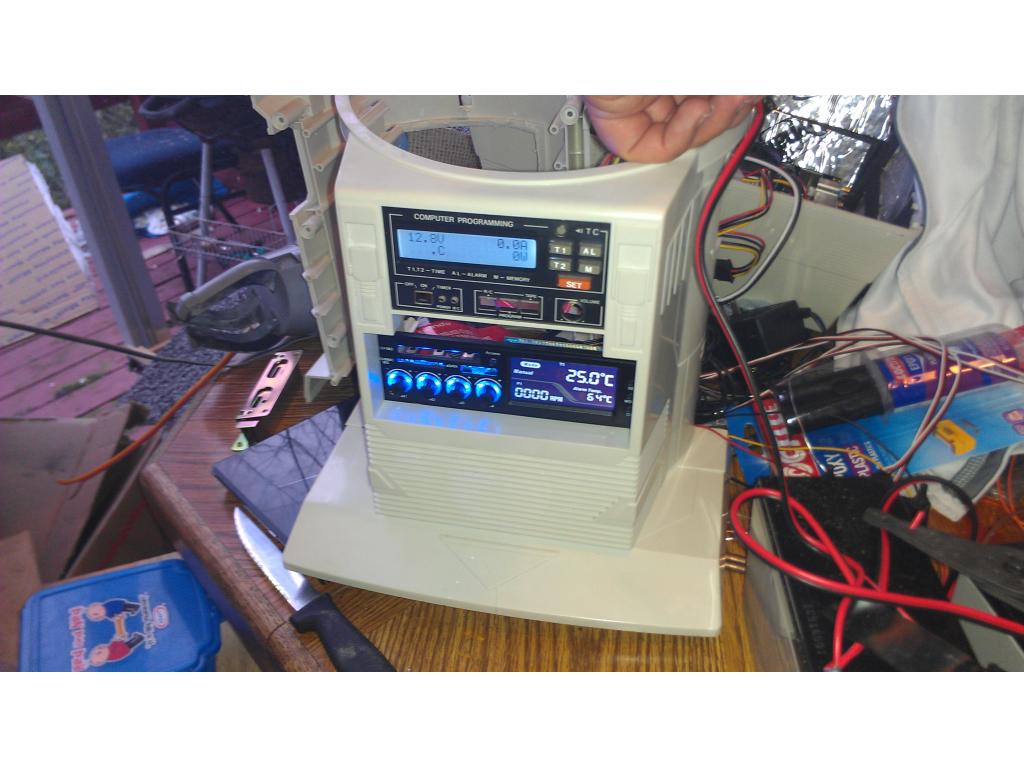
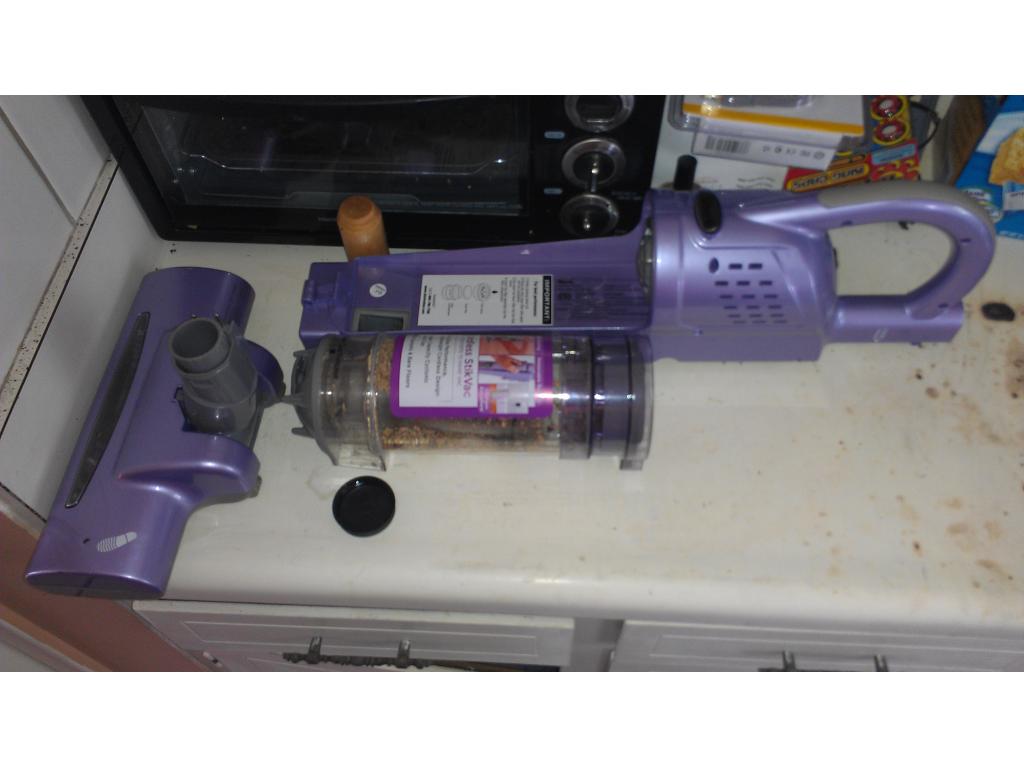
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.
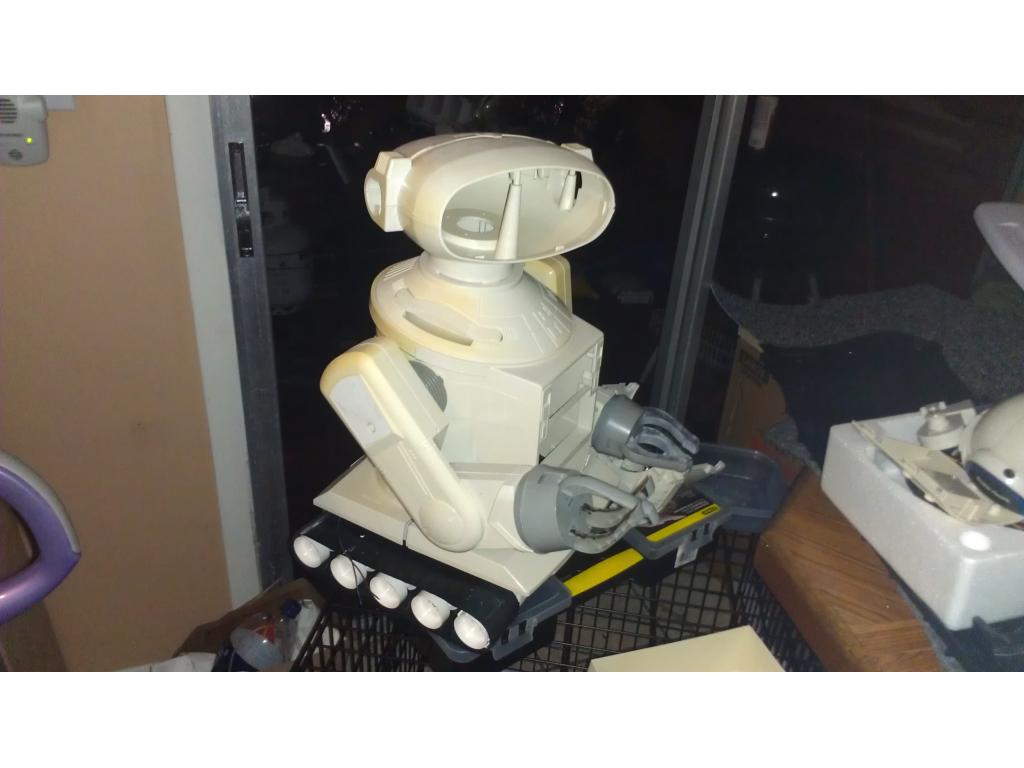
By jstarne1
— Last update
Discover more robots
Moviemaker's Here Are Some Rebuild Pix Of Marti
Marti robot rebuild photos showcasing Hazbot arms, Gizmo neck and assorted borrowed parts highlighting restoration and...
Edison2's R2d2 Star Wars - Kinect!
R2D2 integrated with Kinect using EZ-B showcased at Campus Party Quito-easy robot building with EZ-B, demos and...
Ezang's Another Of My Funny Robots
Moving, talking JD Robot with expressive LED eyes that answers back-playful interactive build showcasing motion and...

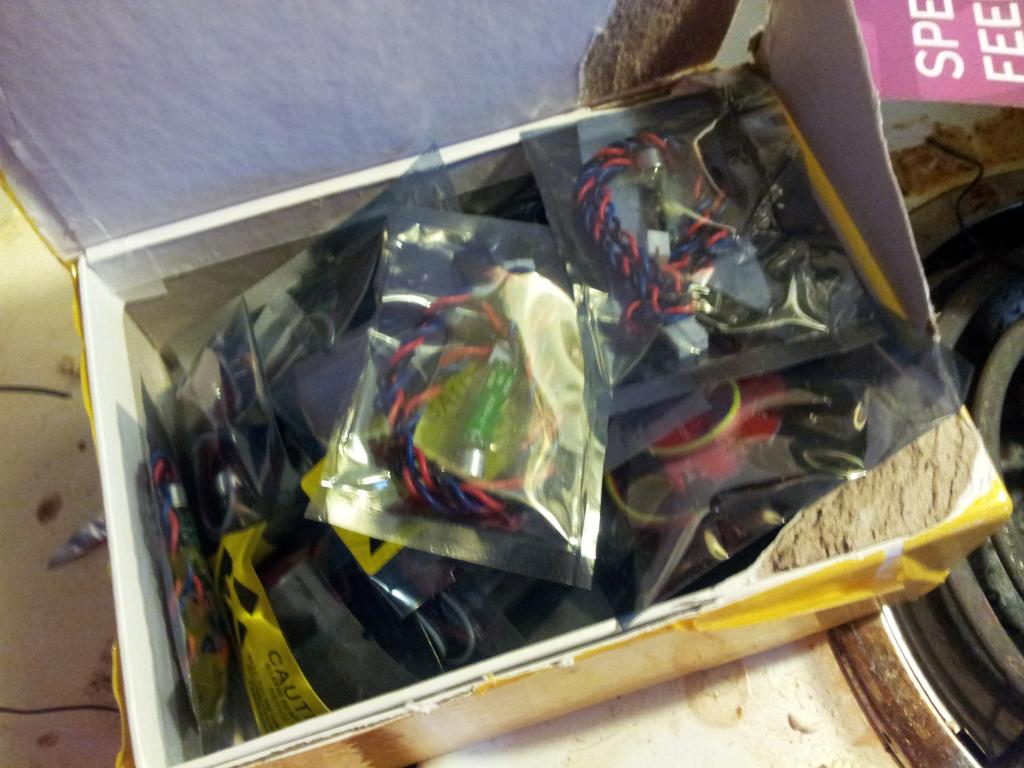
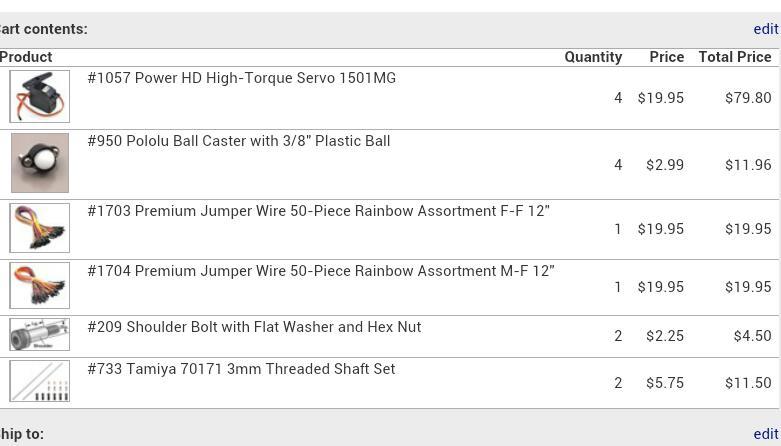
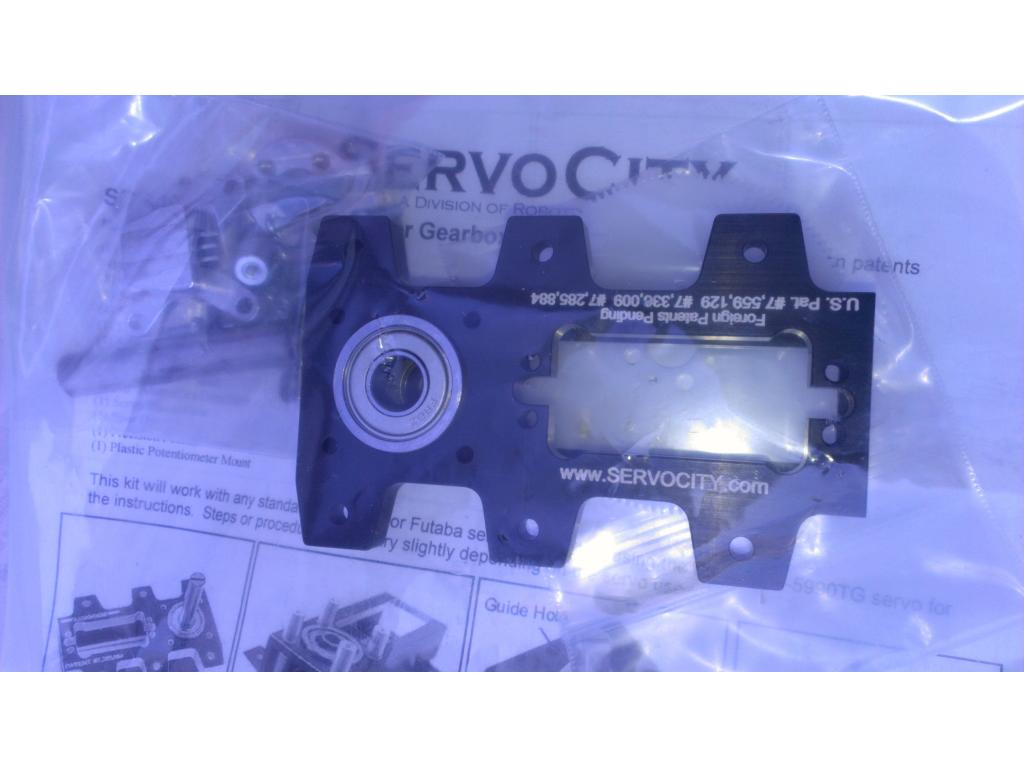
Now that's a goody box!

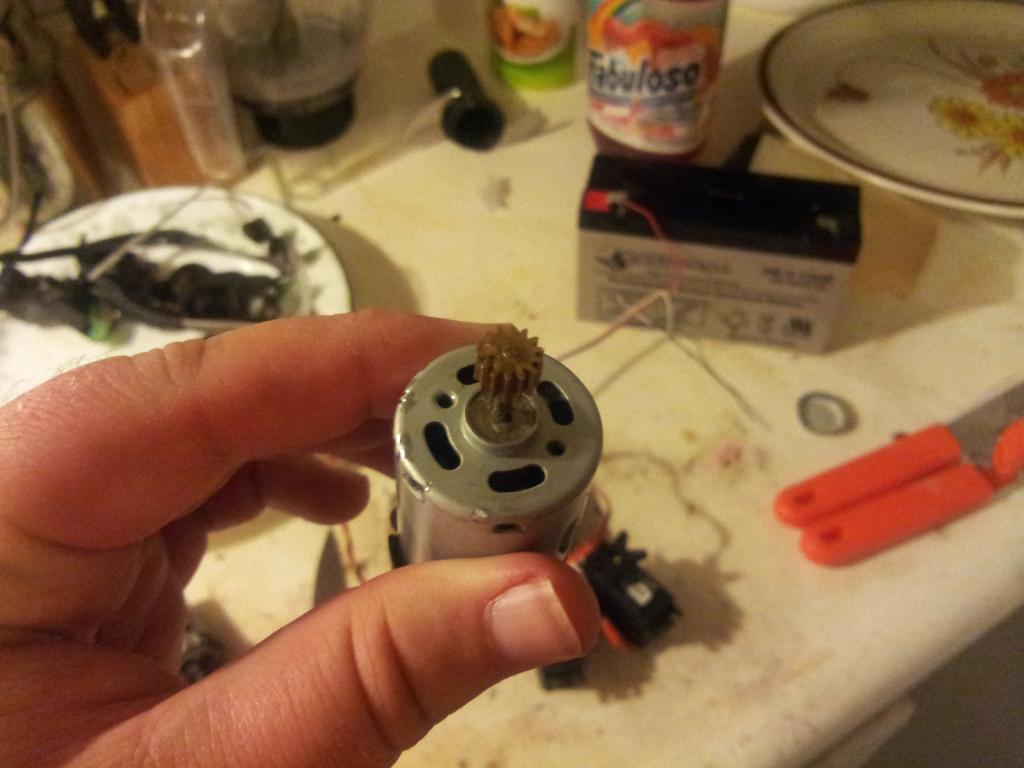
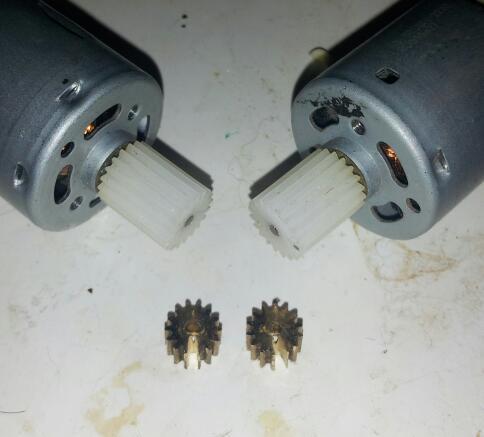
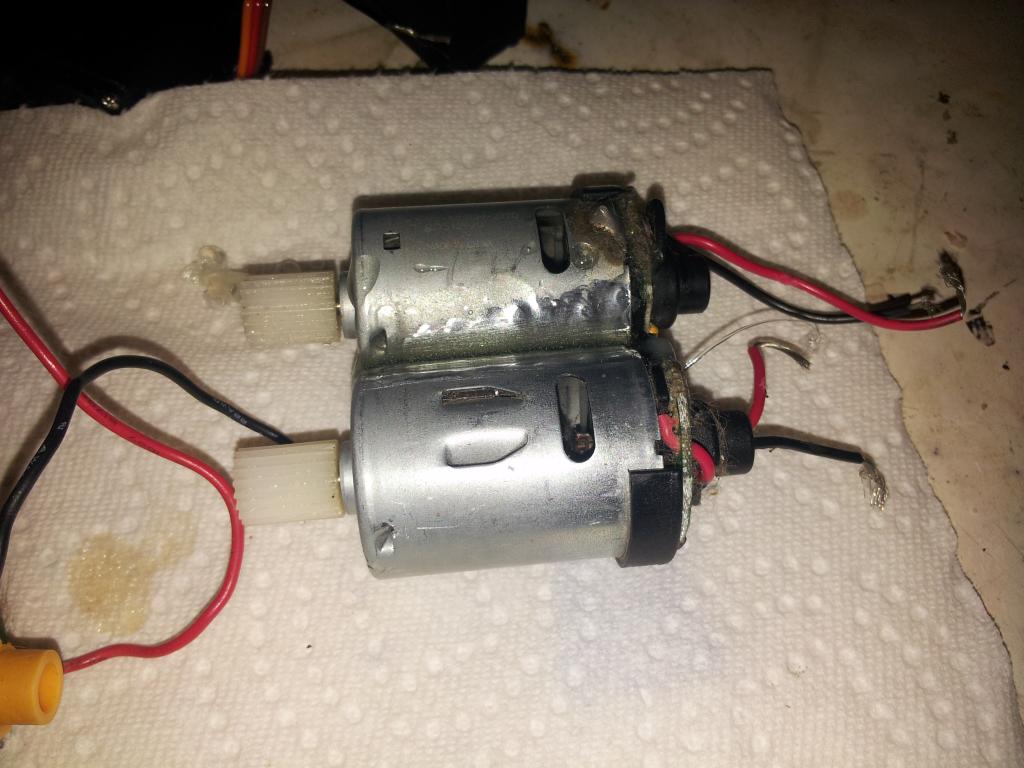
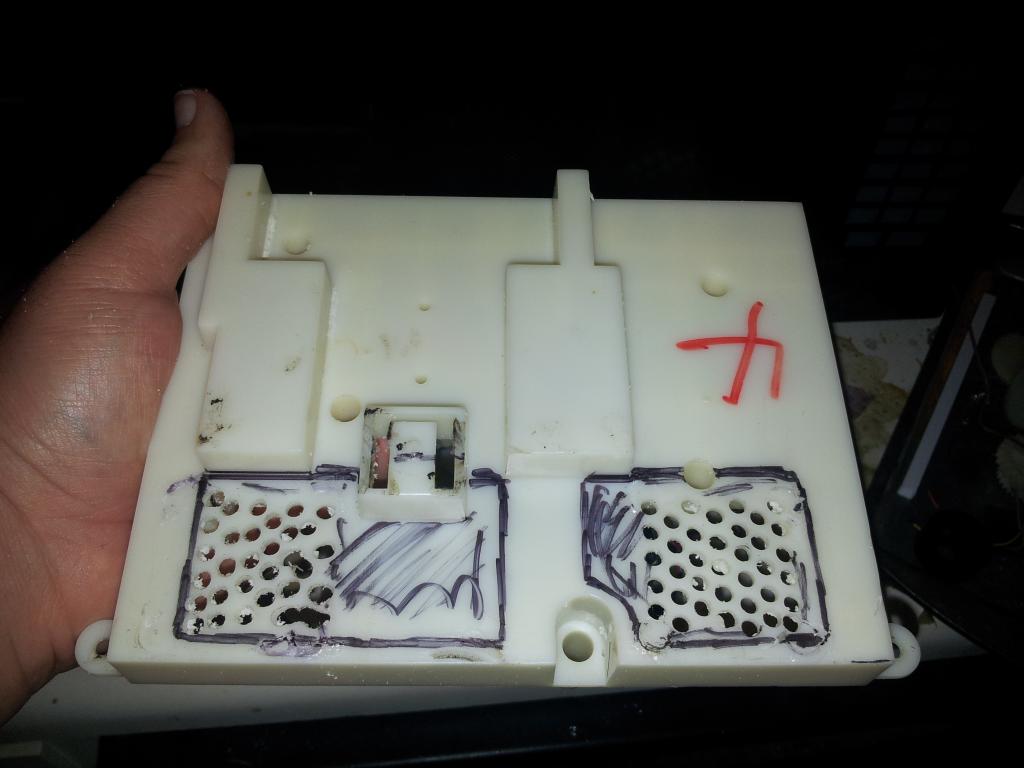
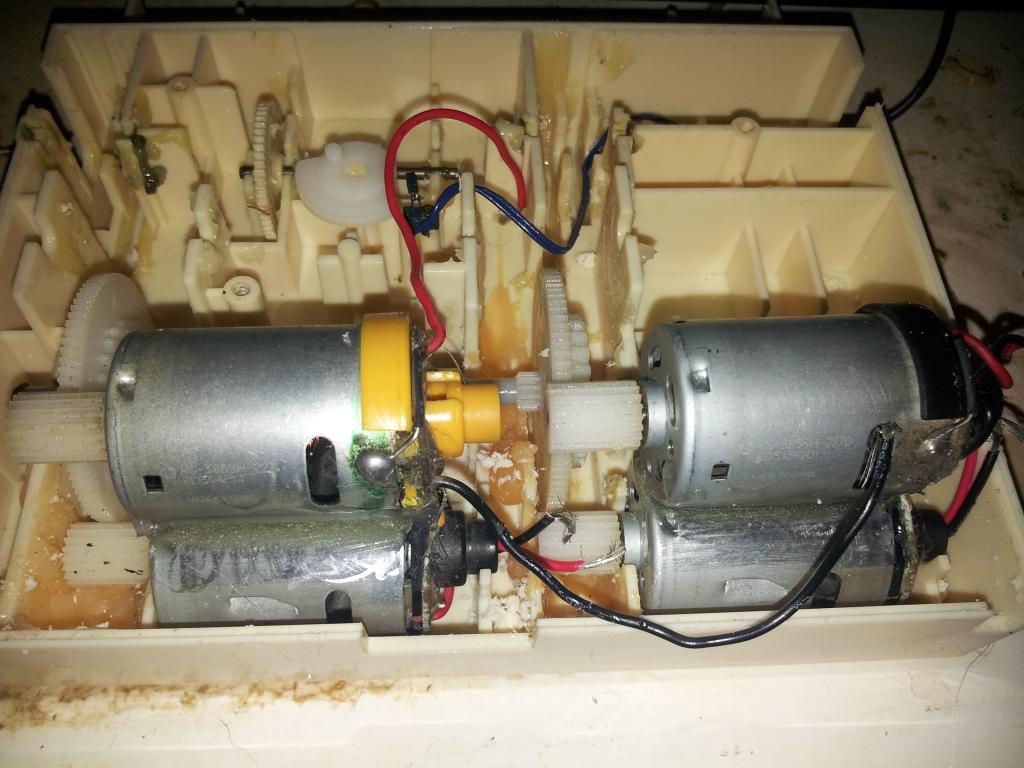
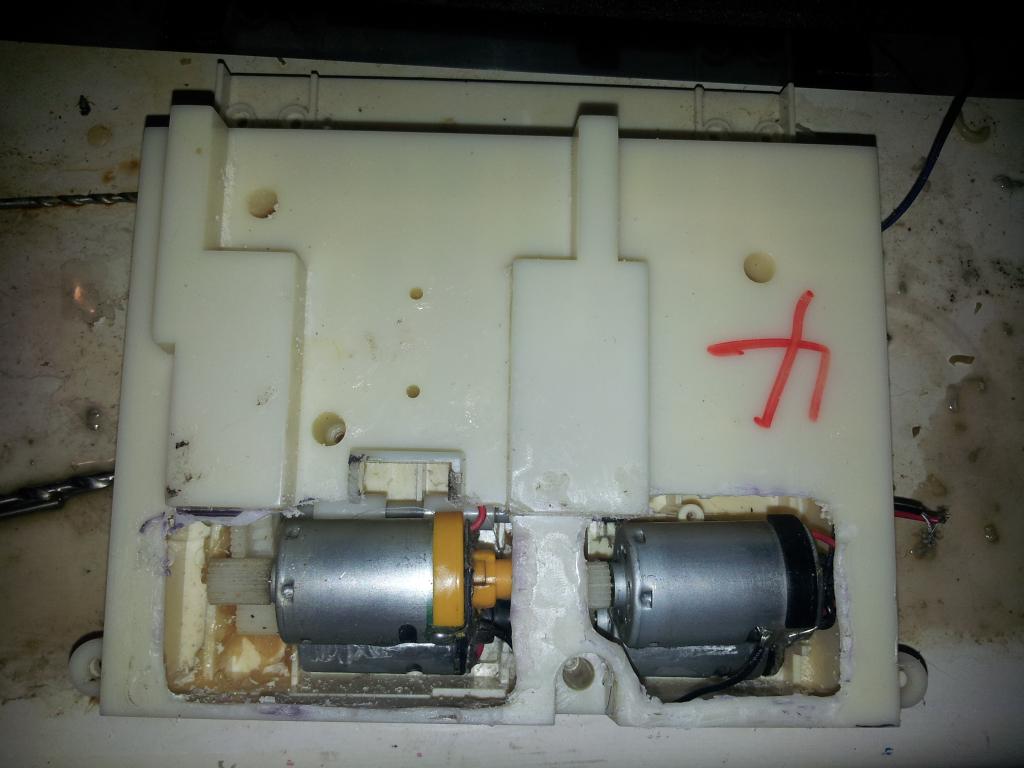
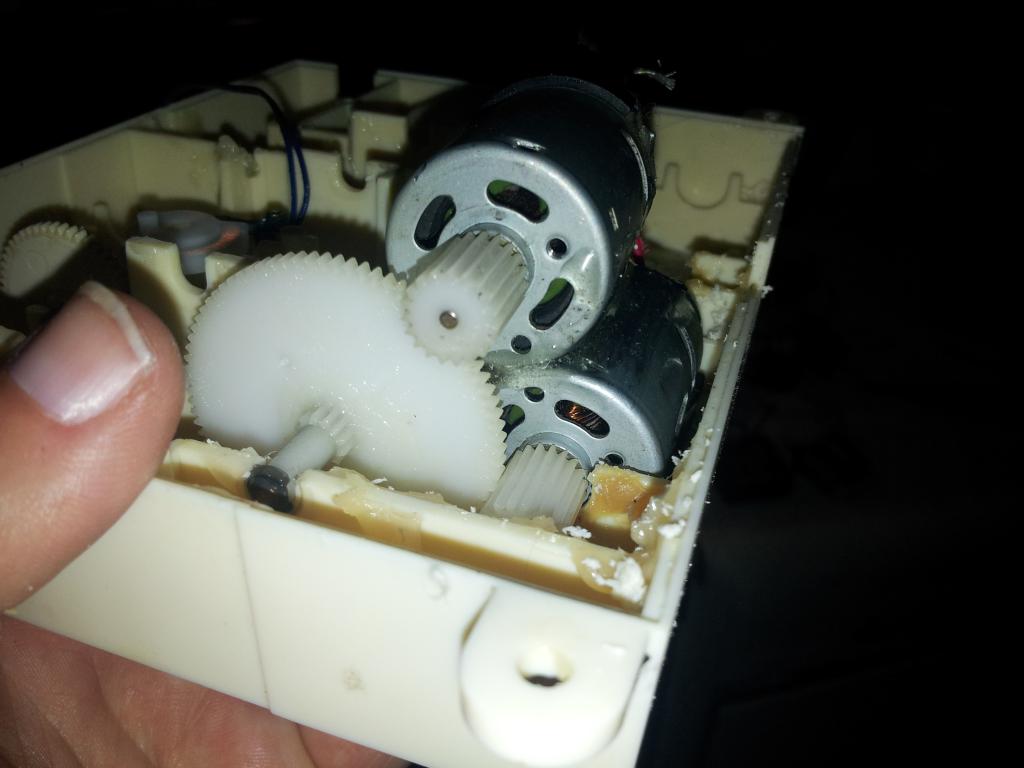
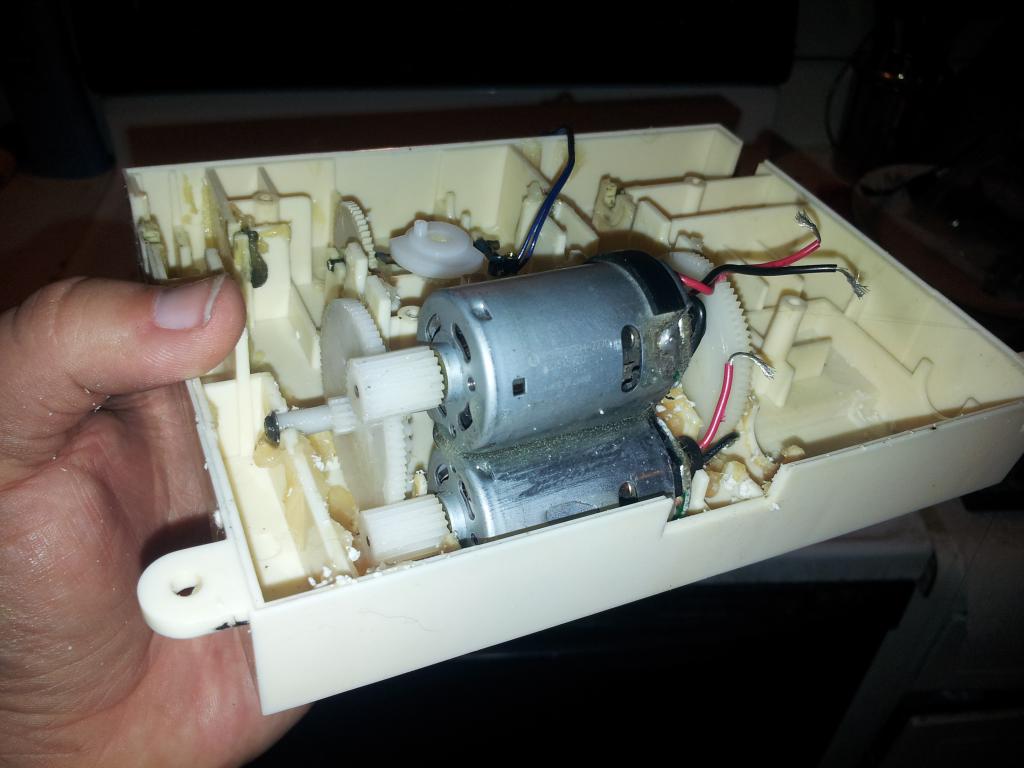
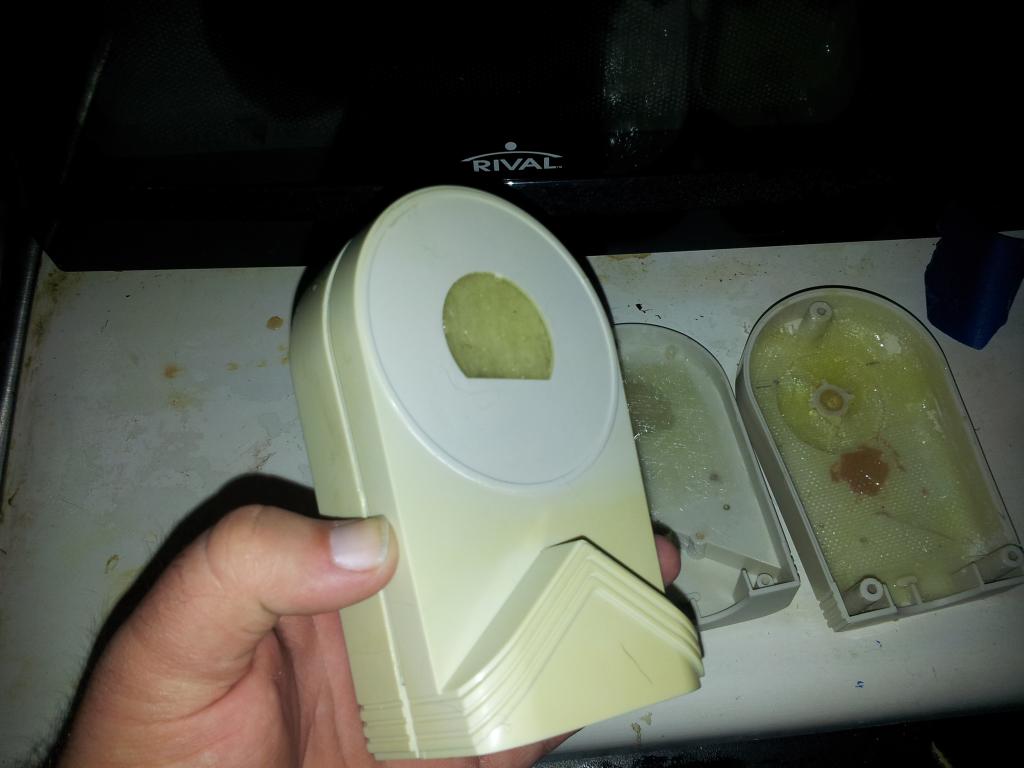
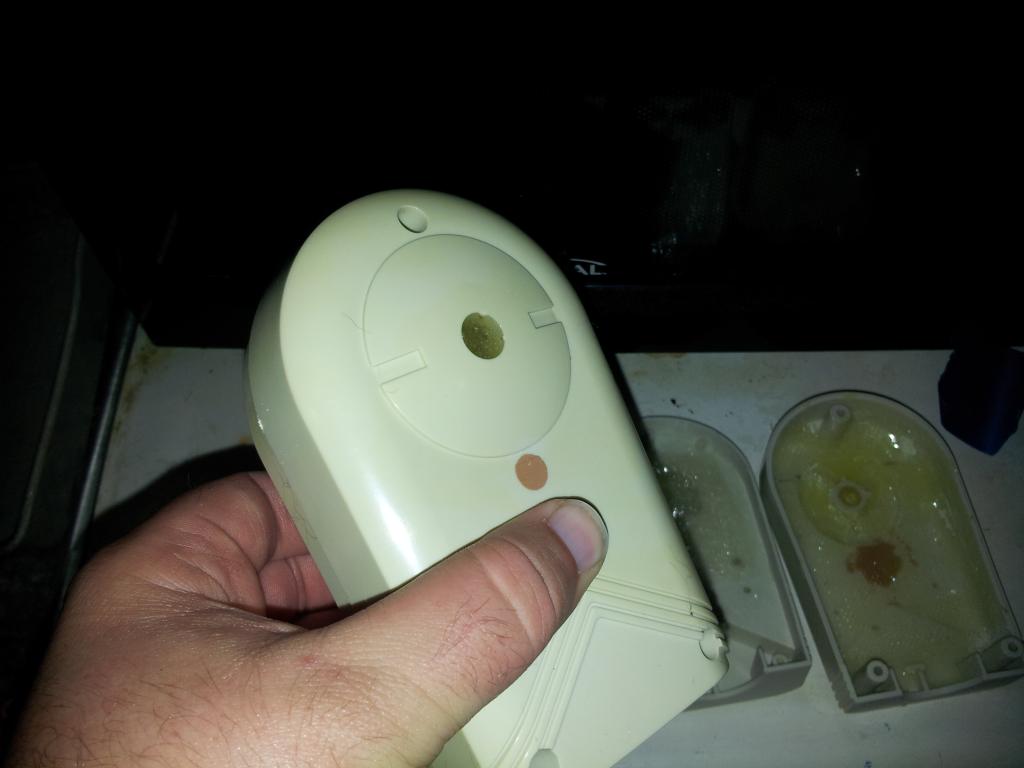
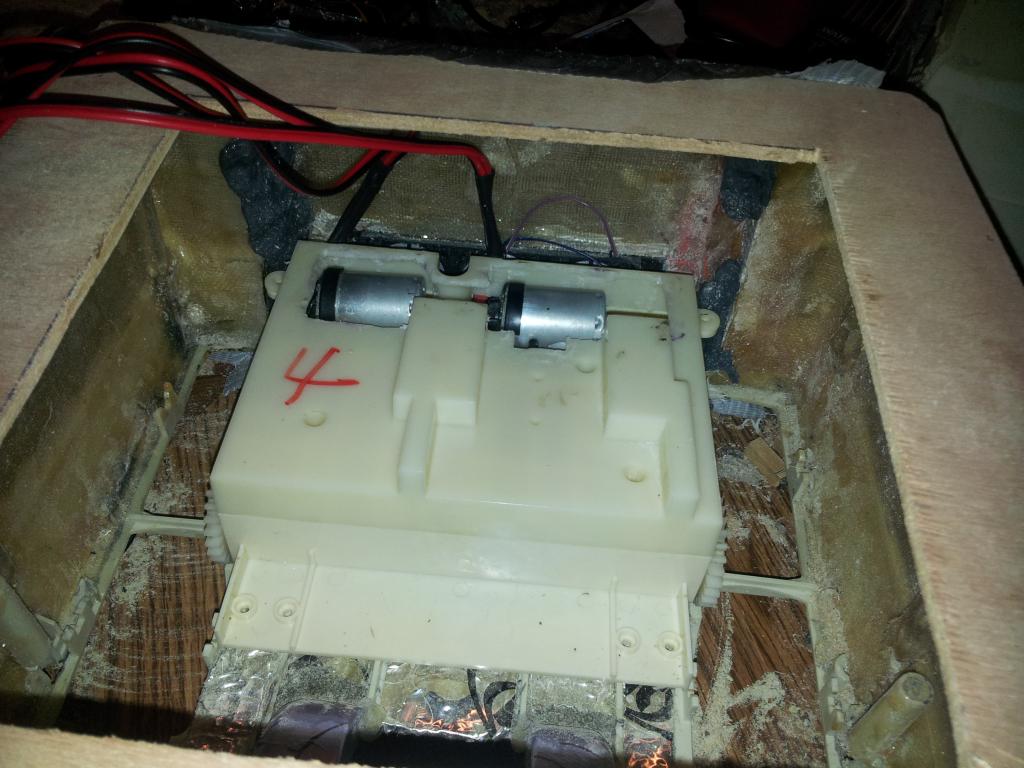
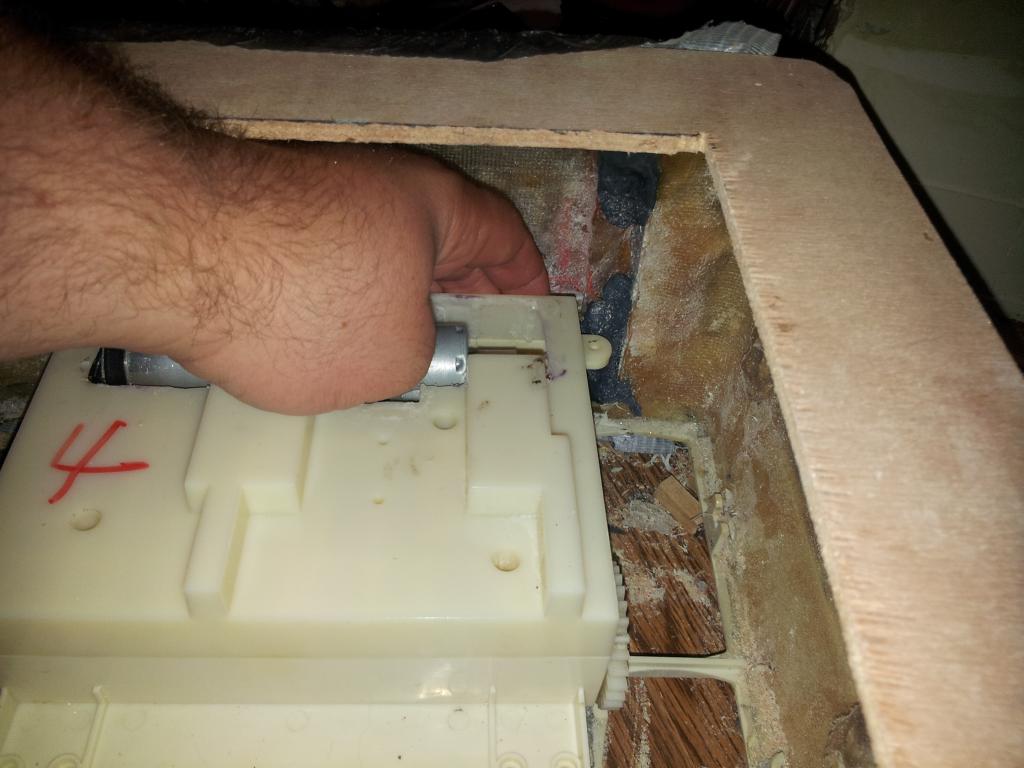
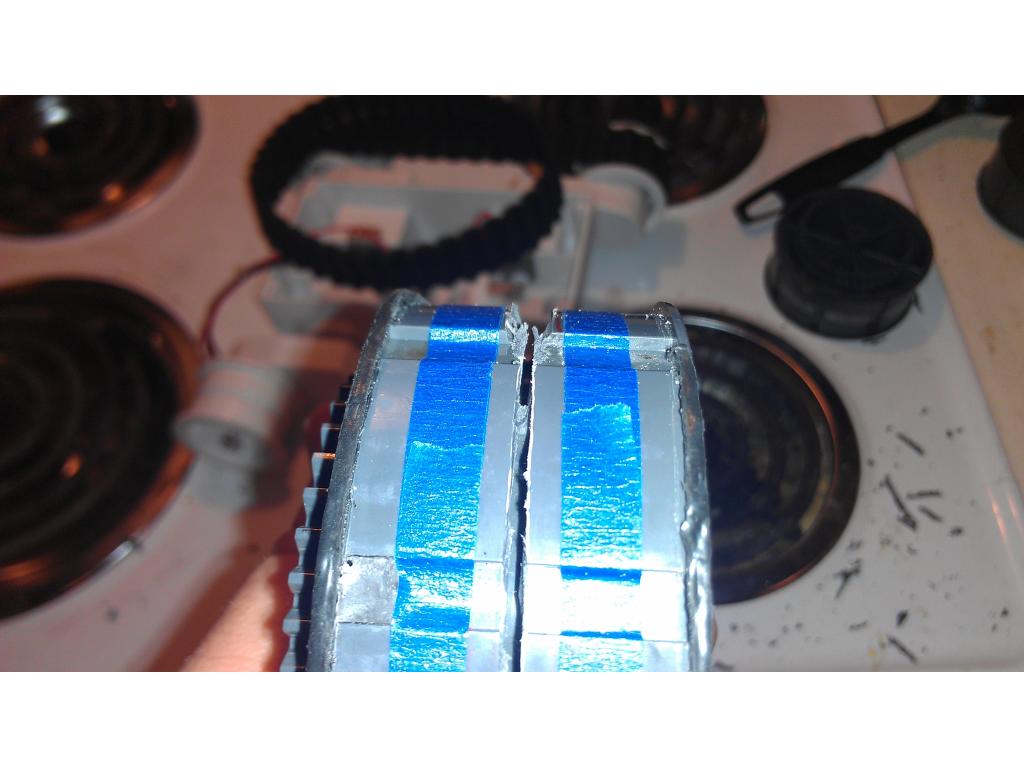
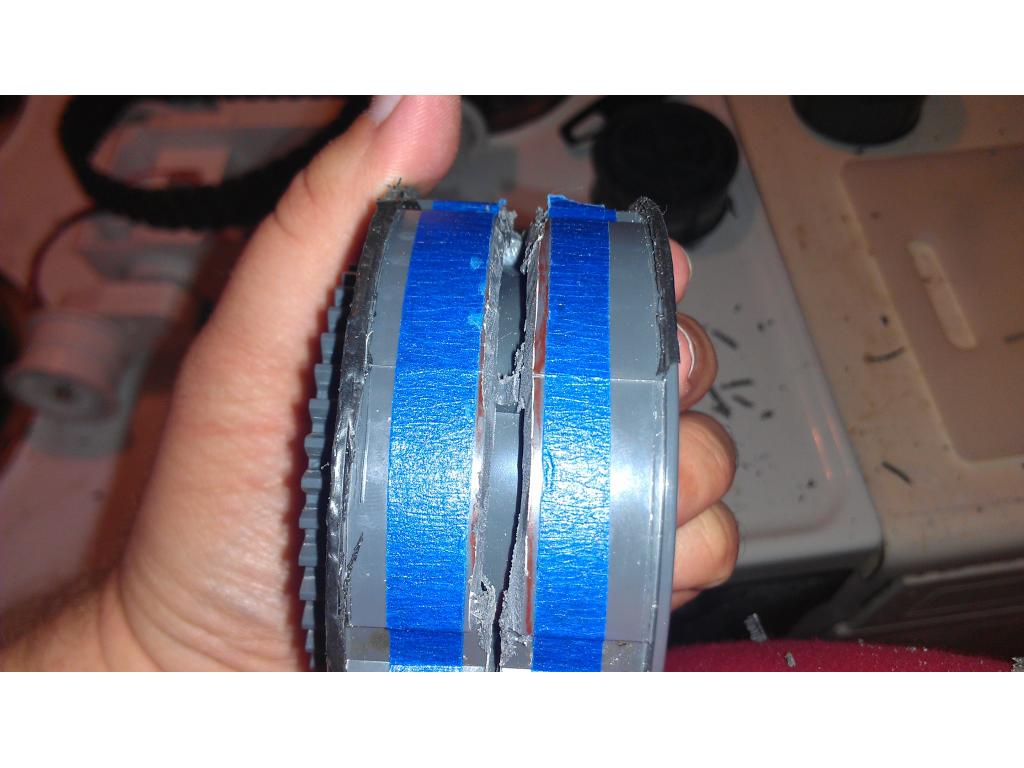
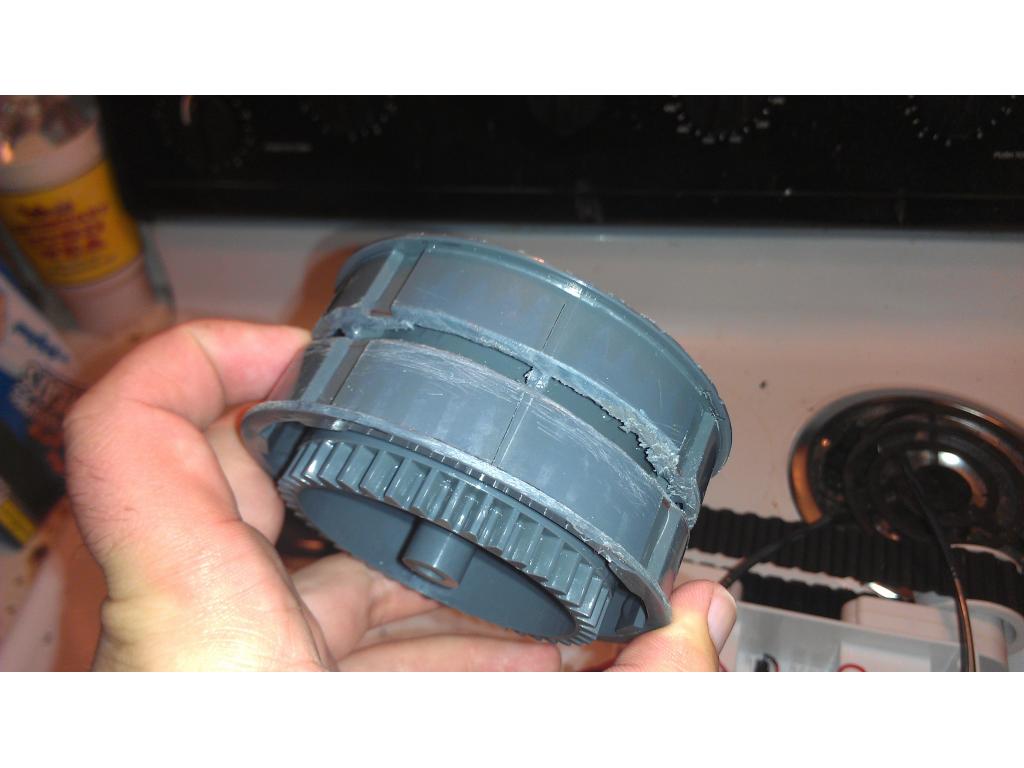
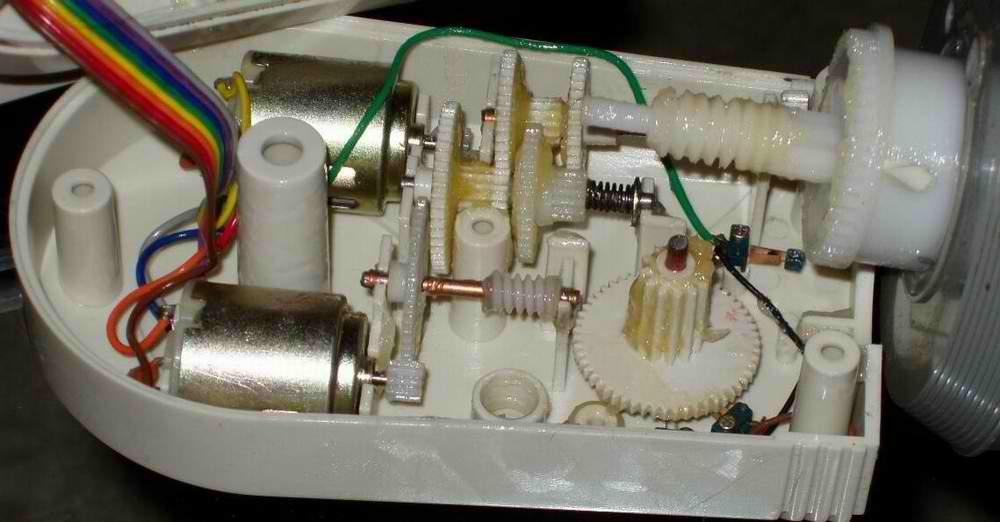
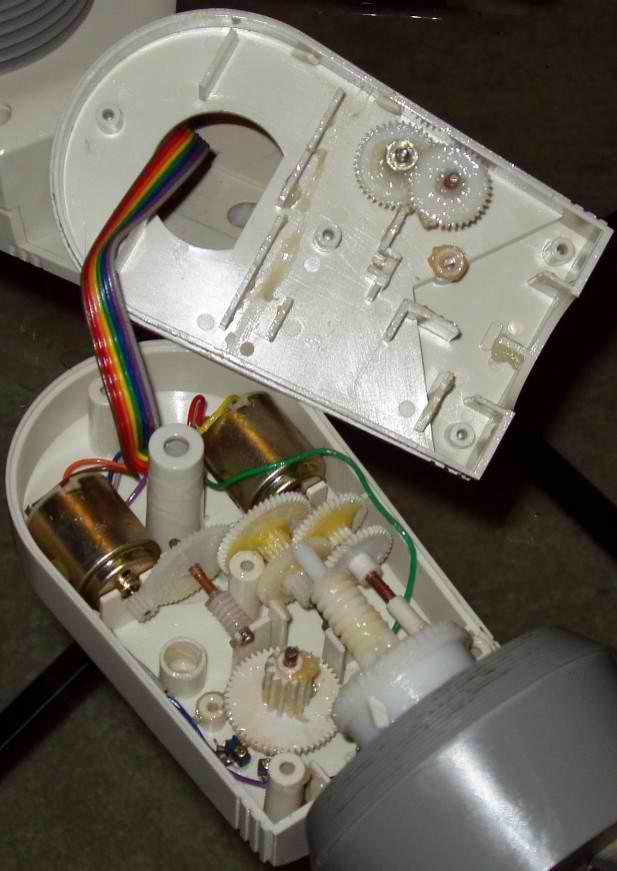
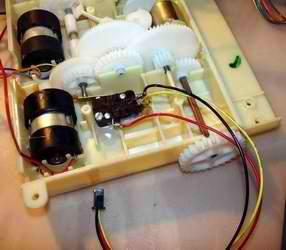
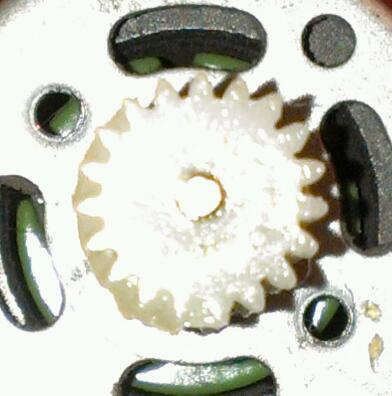
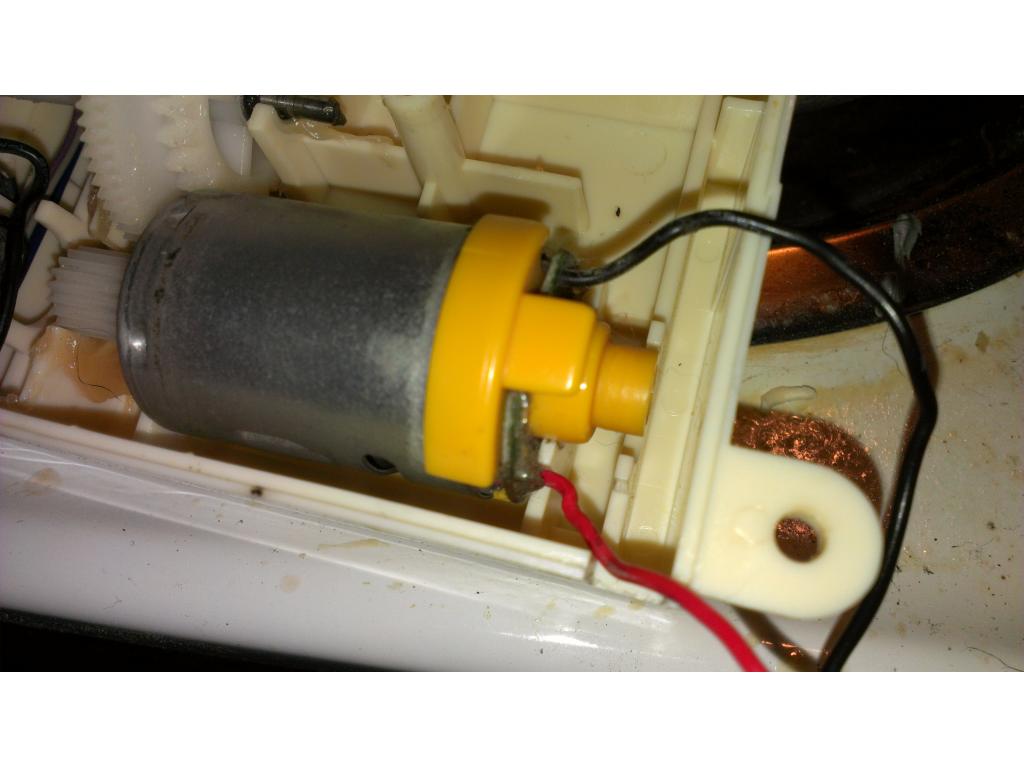
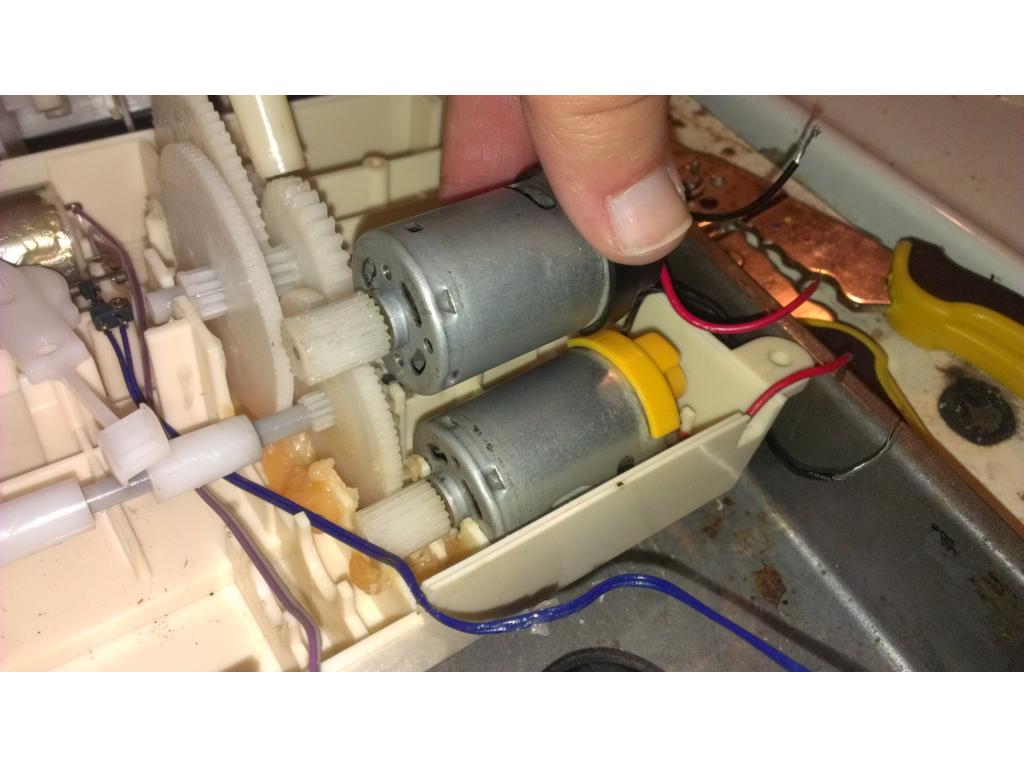
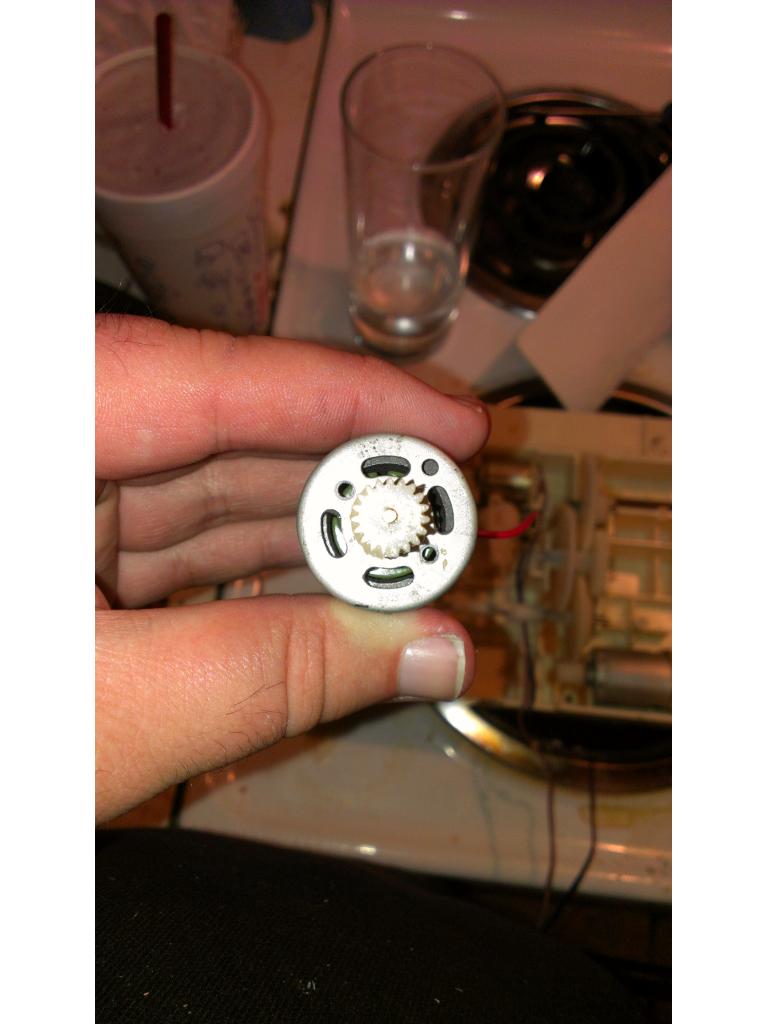
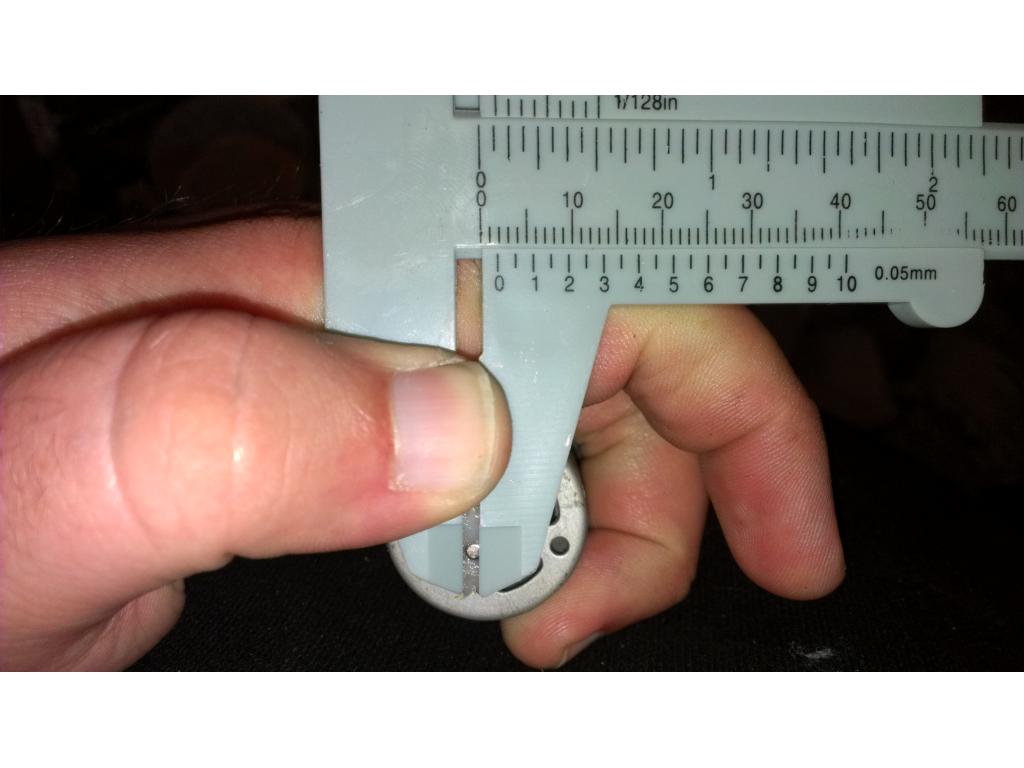
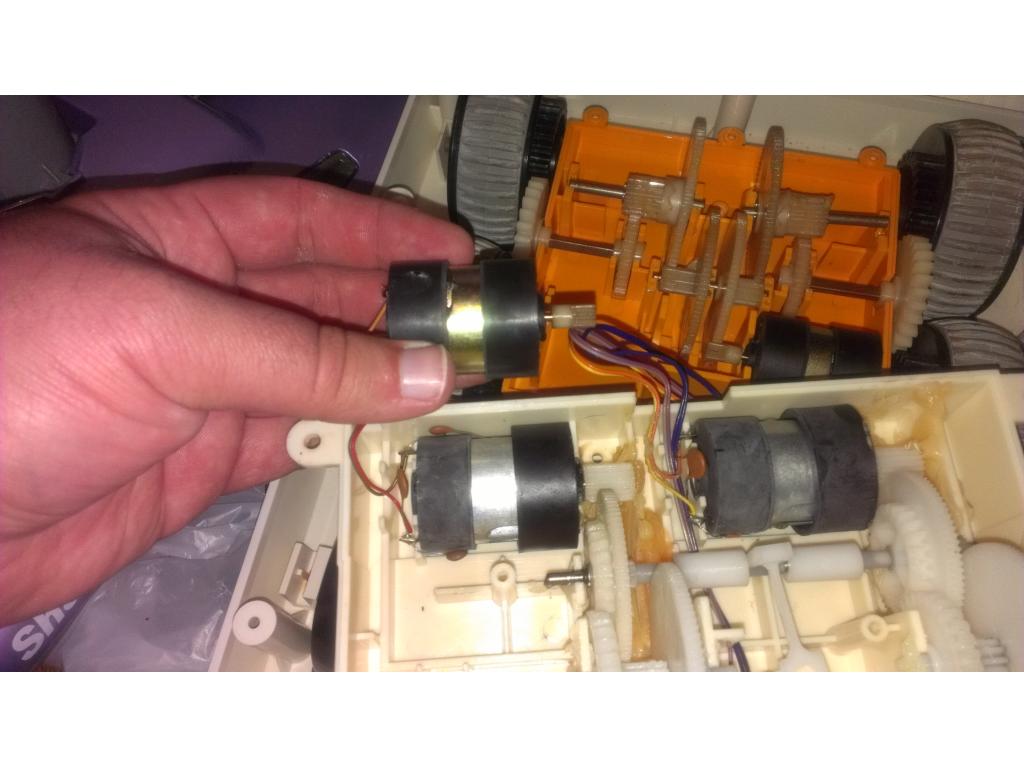
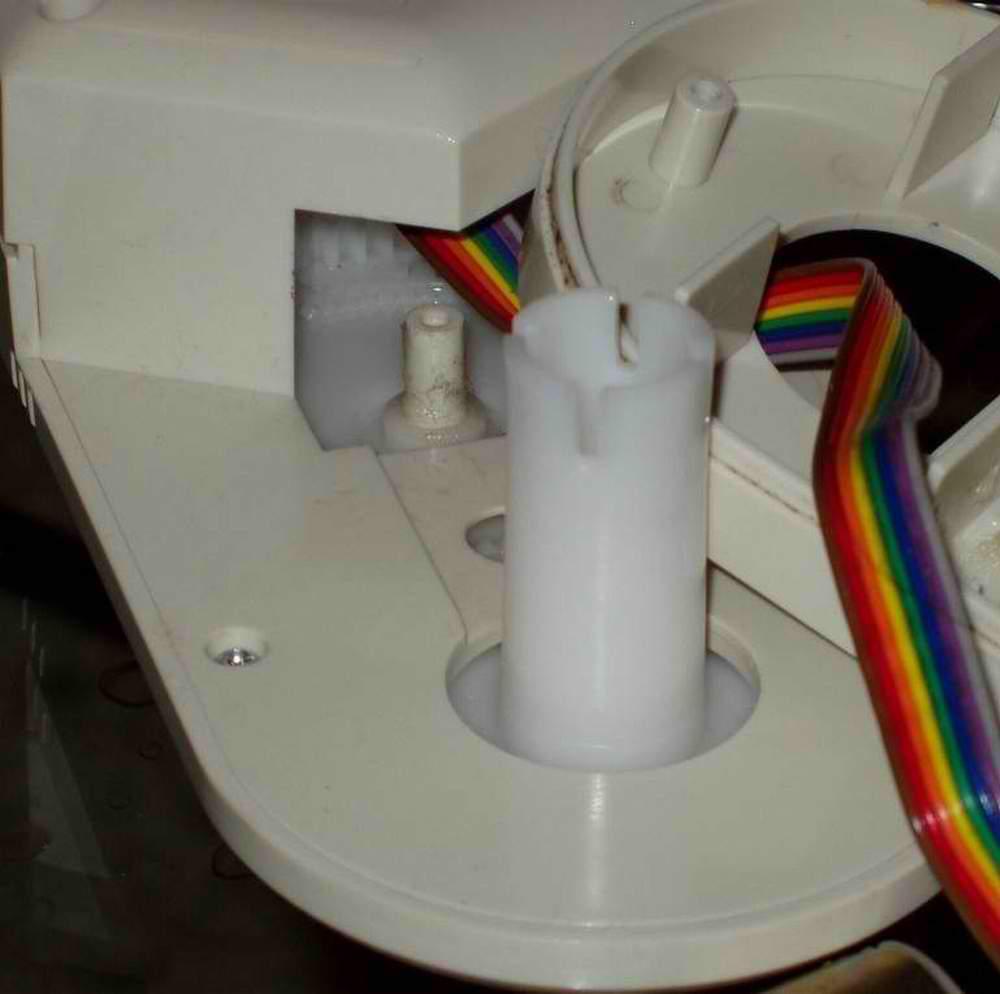
Ok I cut the brass pinions off the shaft which was very easy and tapped on the Delrin pinion from Troy. Next I must cut out the original plastic mounts and adhere two motors together.Ok I cleaned the sides of the motor cases off and cut off the plastic lip so they can be epoxies together. They are.perfect, they are off about a mm but they still line up with the first input spar gear.
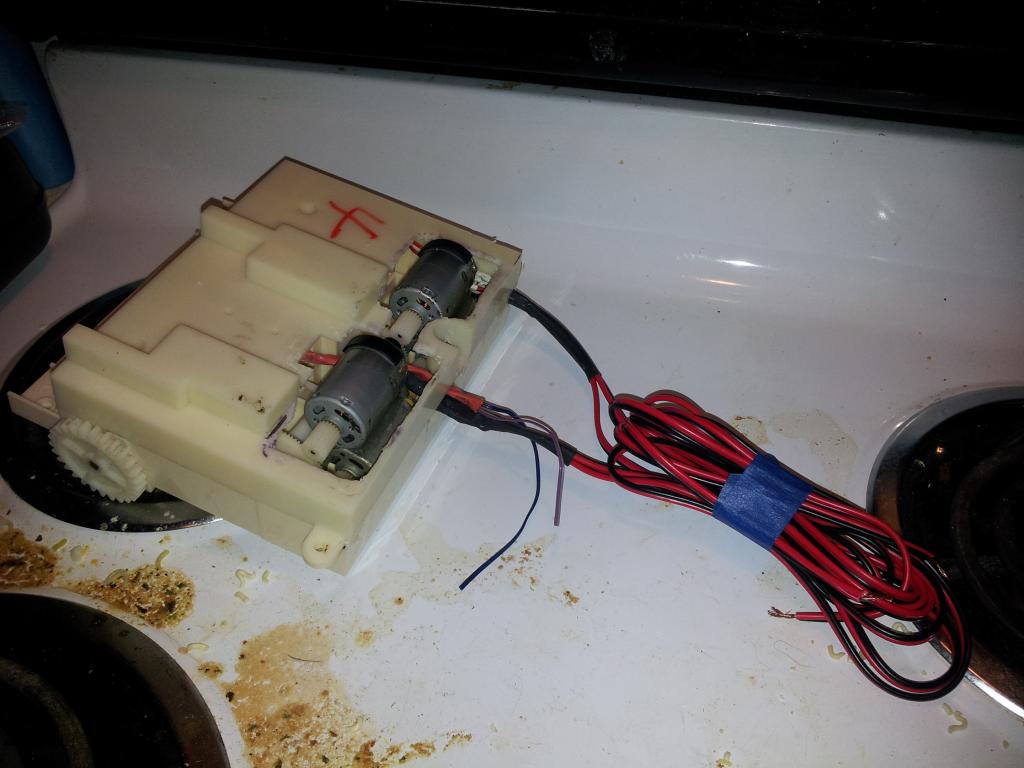
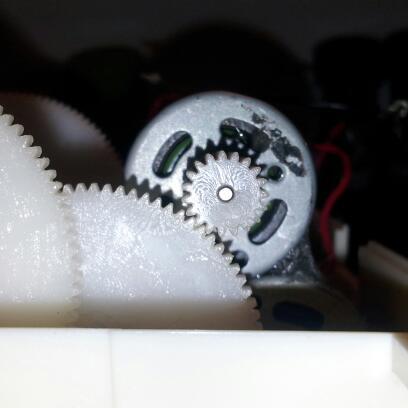
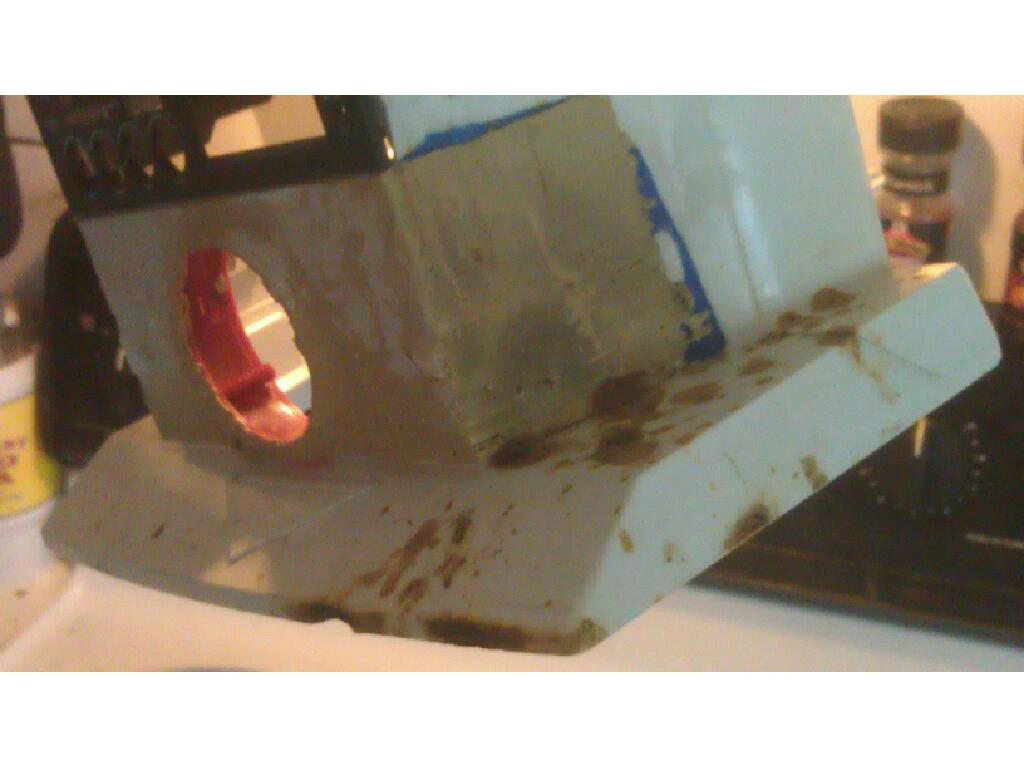
I cut away one mount which was simply too short. Here you can see how two motors would mesh up to the input spargear.
Ok I checked out the meshing on the gears, they look to fit together well. I did a HD test video, sorry about the noise the camera is like 12 inches and sometimes closer to the gearbox which has no grease in it or a cover.
Test video!
https://www.youtube.com/watch?v=Q5w6XiU_3Ho&feature=plcp