


Hi,
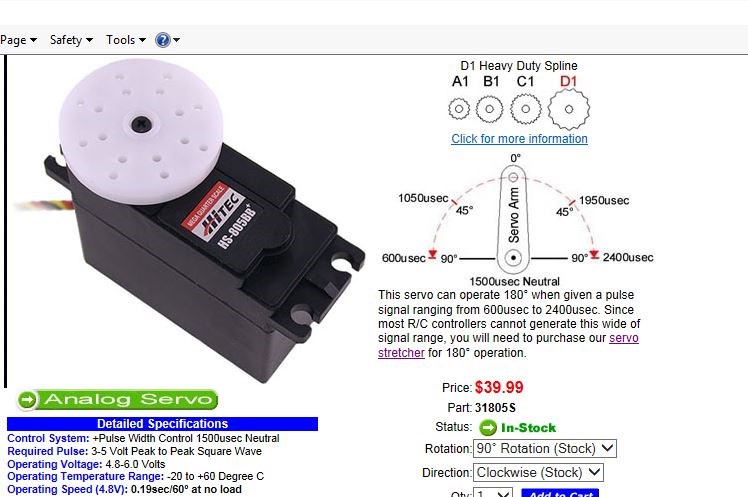
I am using multiple HS-805bb Servos. I can not seem to get full 180 degree movement using the servo controller. Is there another controller that works better? See image for specs on this... it seems I need to give it a longer pulse?
 Read Digital
— Read TTL digital input from an ARC I/O port; real-time red/green status for low (0V) or high (+3.3/5V), selectable board/port and read interval.
Try it →
Hi,
I am using multiple HS-805bb Servos. I can not seem to get full 180 degree movement using the servo controller. Is there another controller that works better? See image for specs on this... it seems I need to give it a longer pulse?

Do you have a cheap standard servo to test? That way you can at least eliminate ARC as the problem...
Hi,
I constructed and installed the Shoulder and Bicep to 3 relays. At first I could not get the relays (HS-805BB) to rotate more than 180 degrees. I opened the relays as suggested on InMoov site, cut the stops and removed the potentiometers. I did this on 2 relays, not the 3rd. That one I just took the connector out so that it could use the potentiometer. The other 2 I left hanging out for now. I was able go in either redirection as much as I want by just pulsing it as many times as need to move the relay where I wanted to go. I do not know how or if possible to find a certain position to place the servo. Any one with ideas let me know.