
Hey,
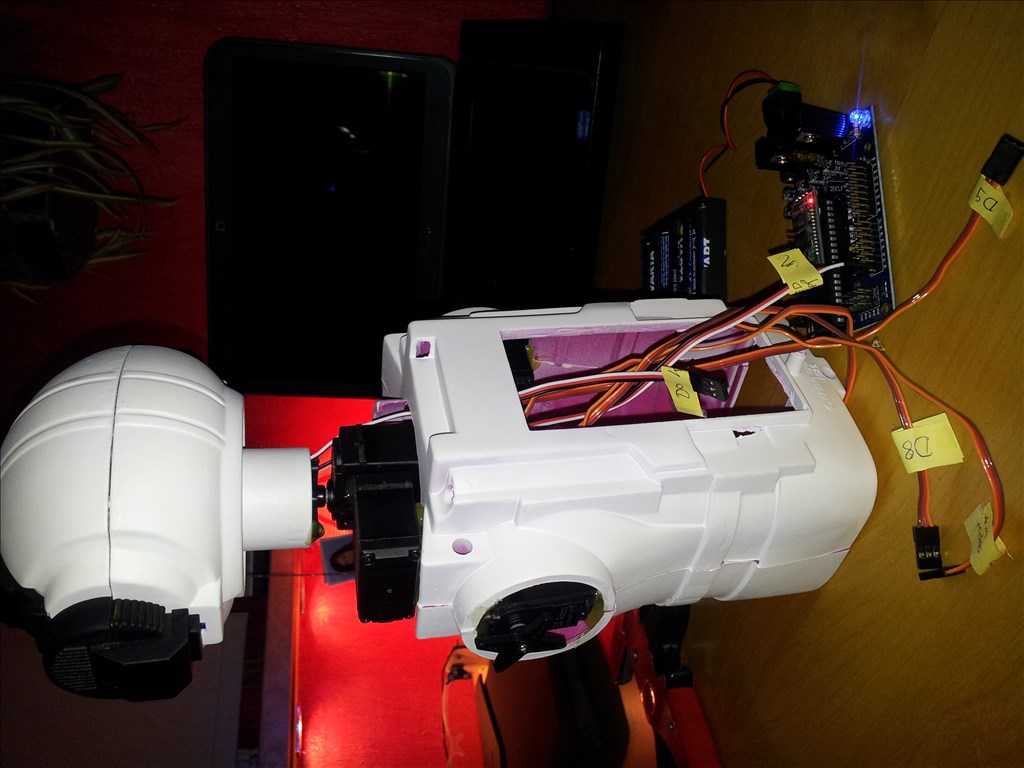
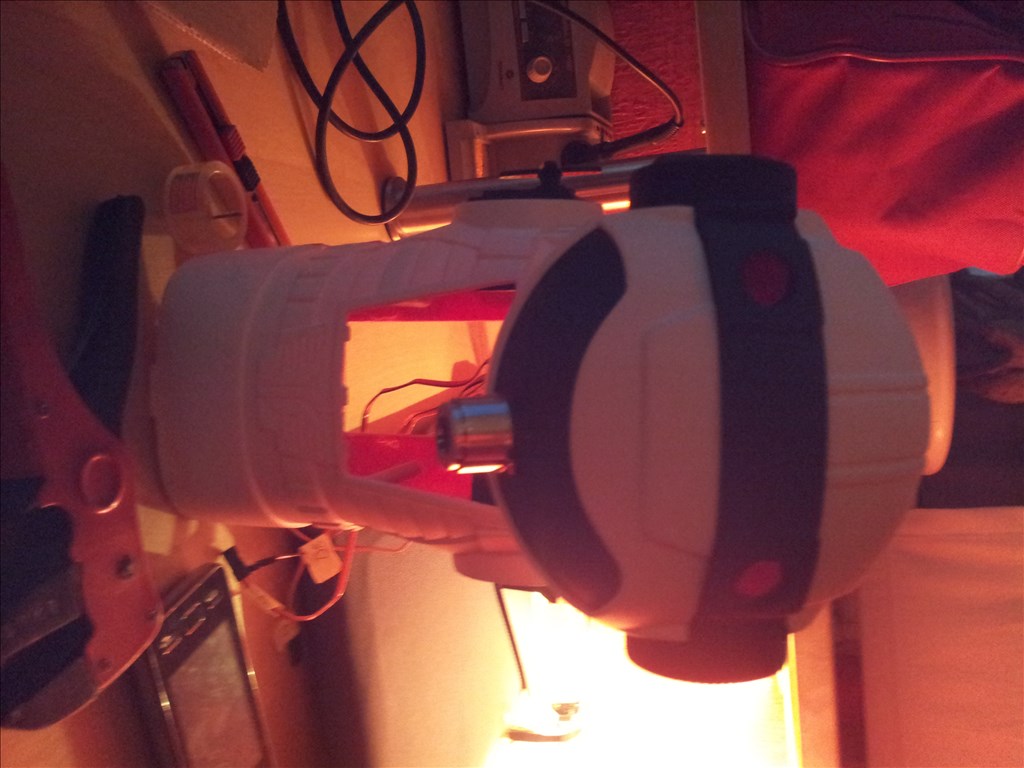
here´s my first robot-project.
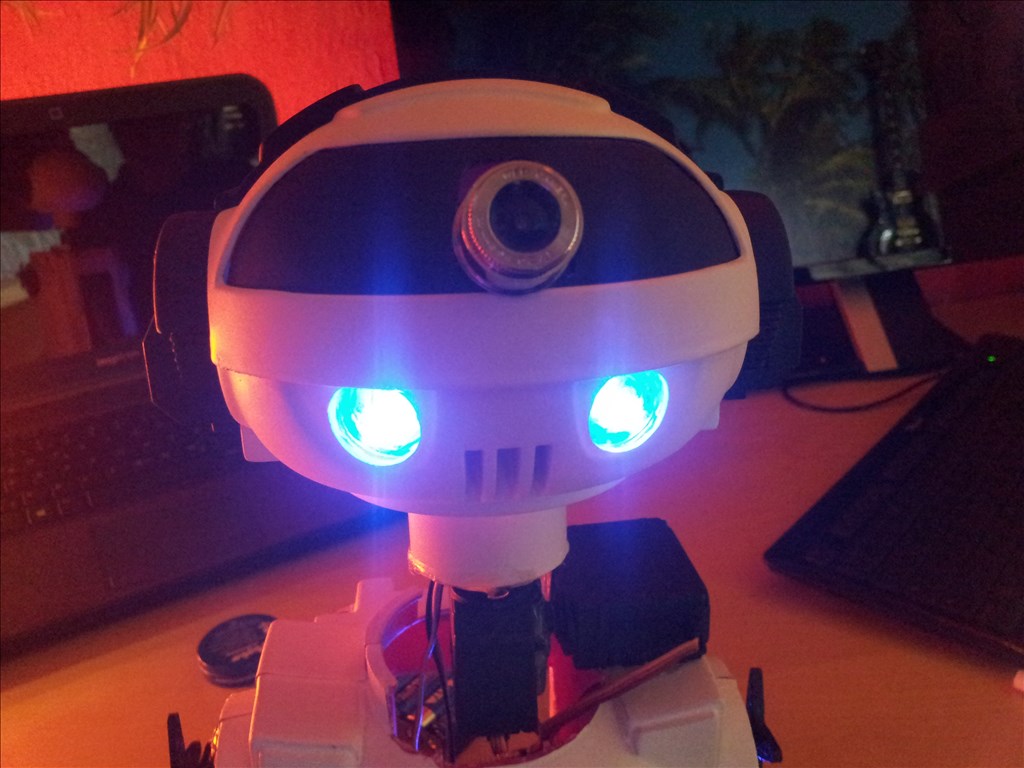
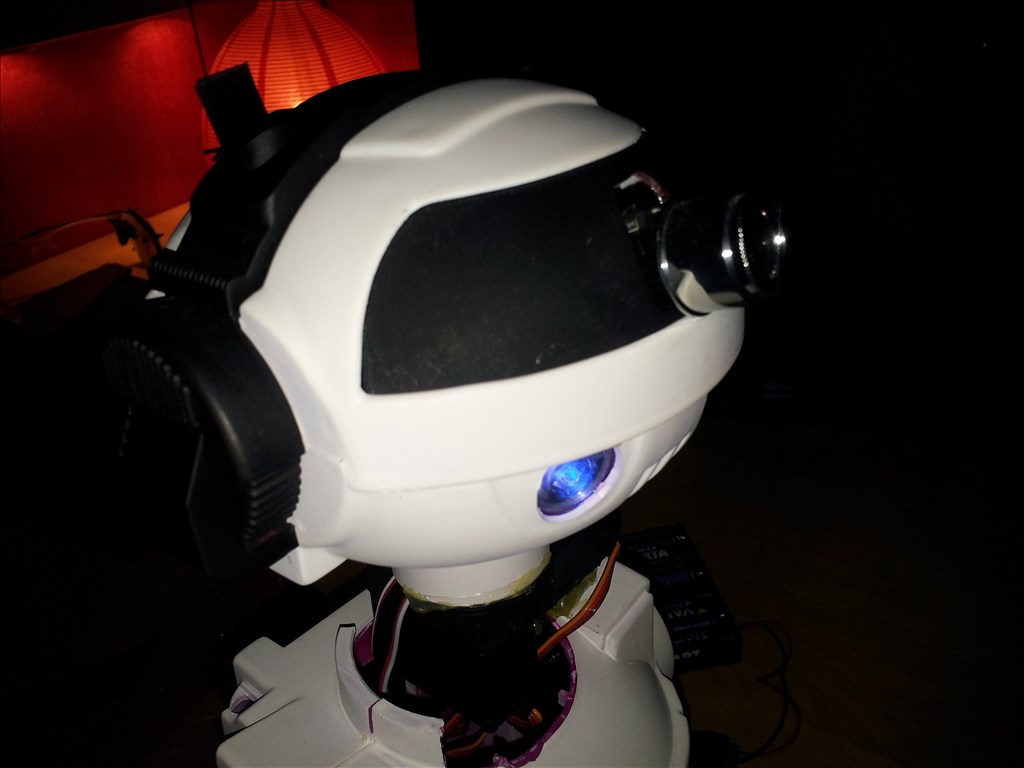
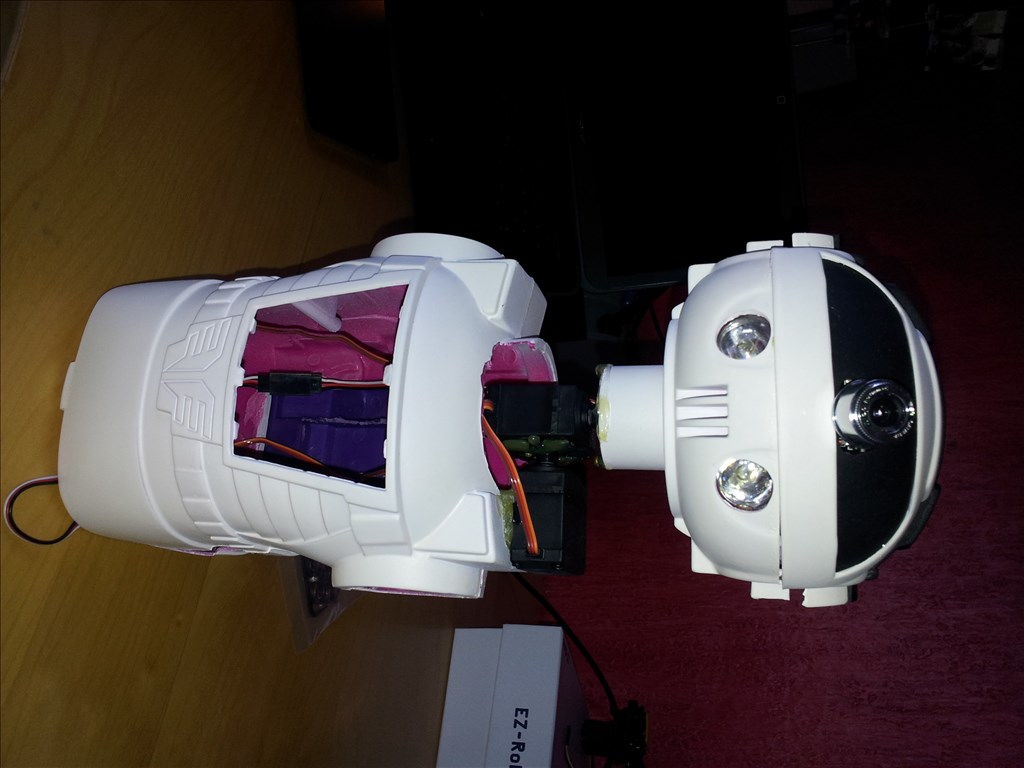
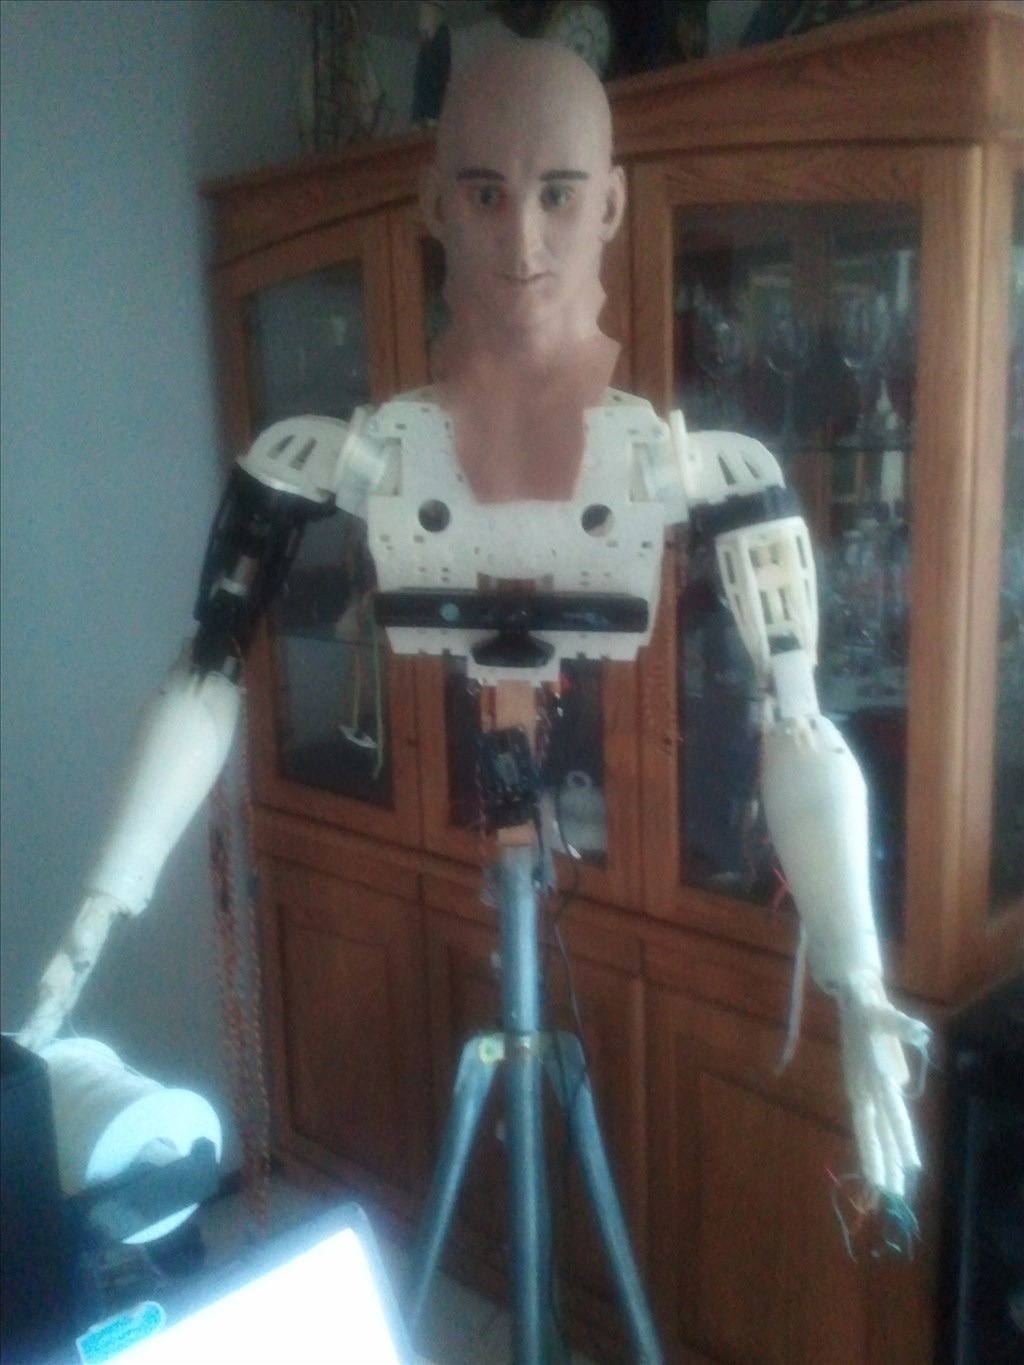
I proudly present "MARVIN" tadaa
As you can see, I´m still working on it ...
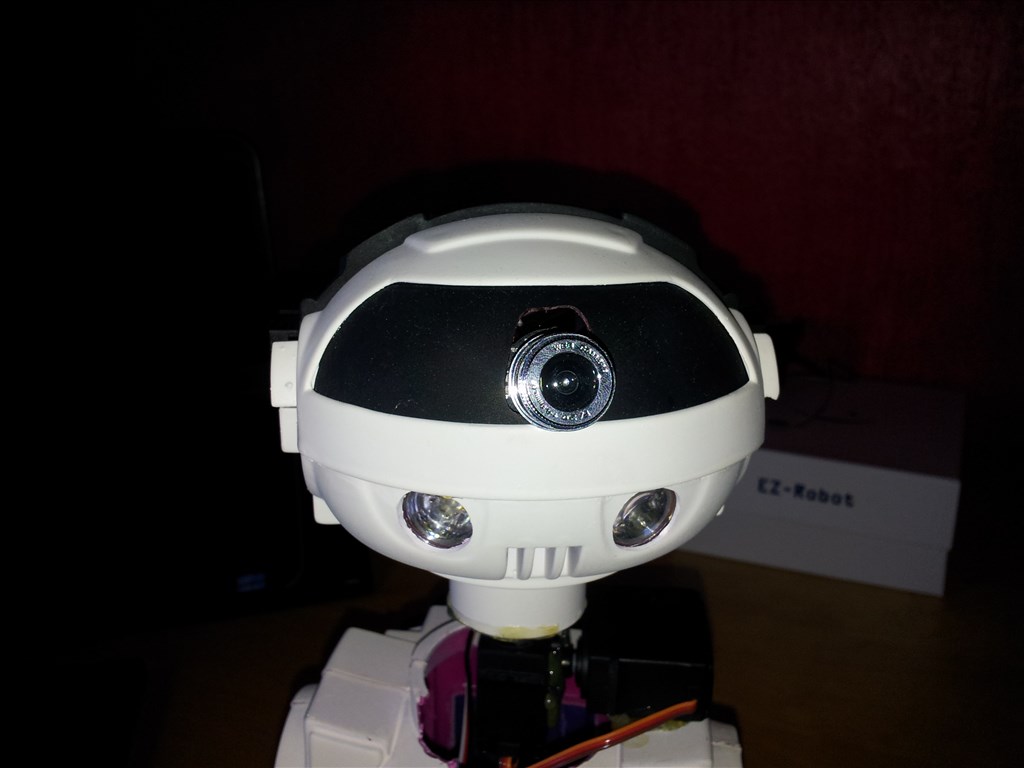
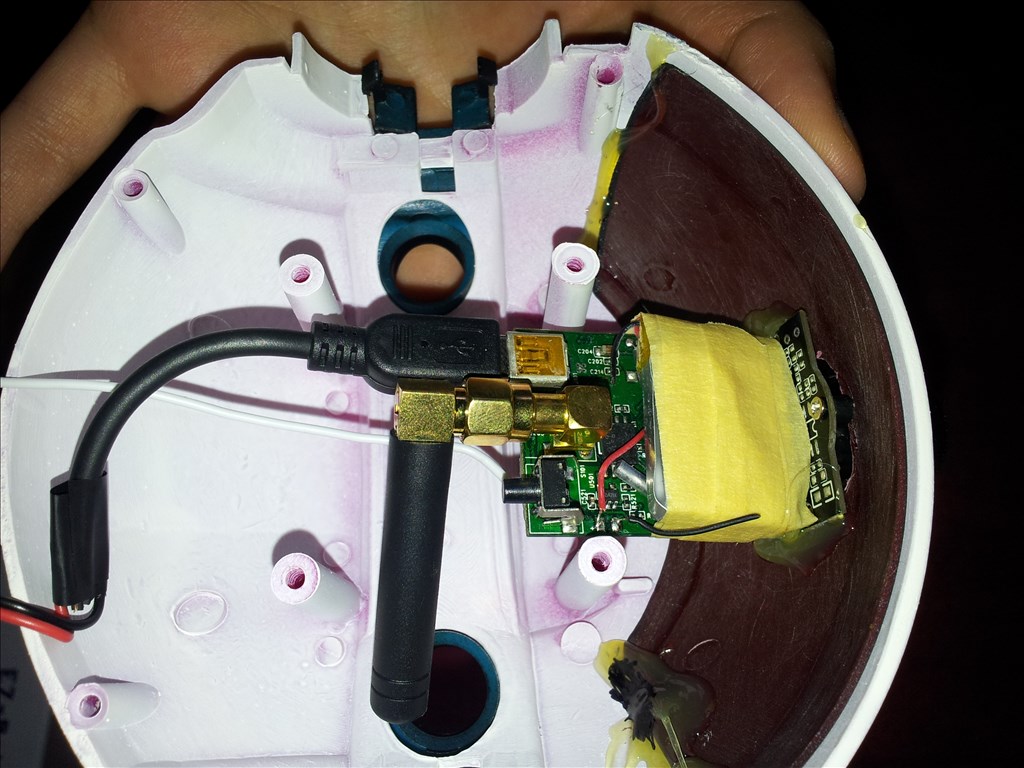
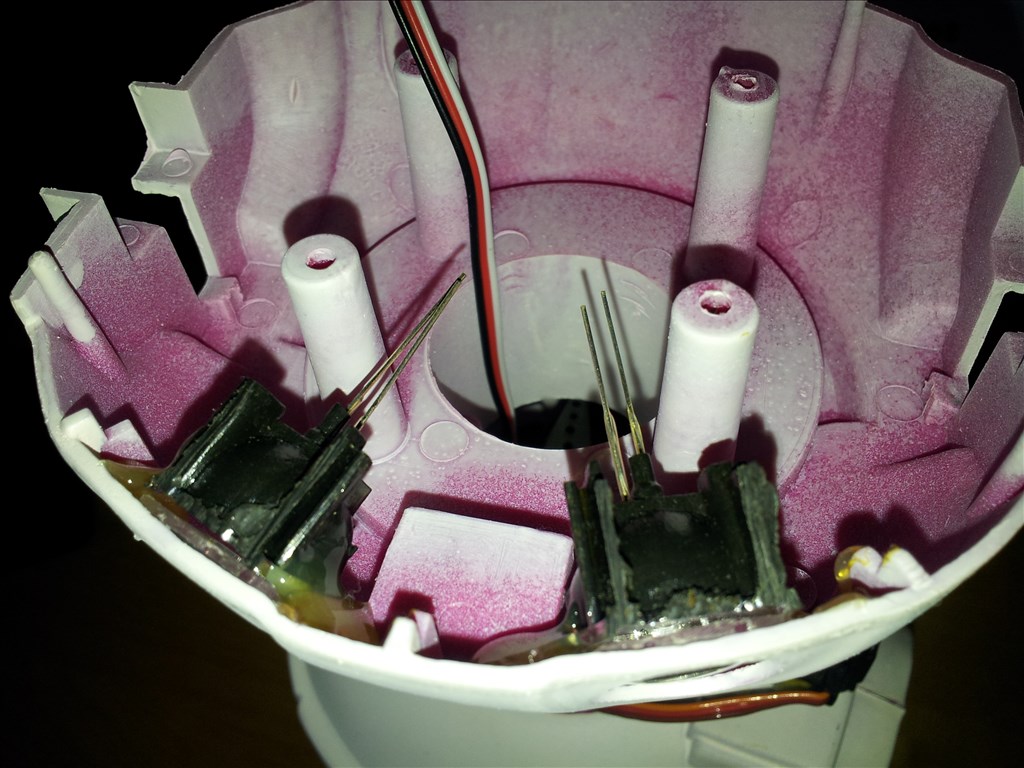
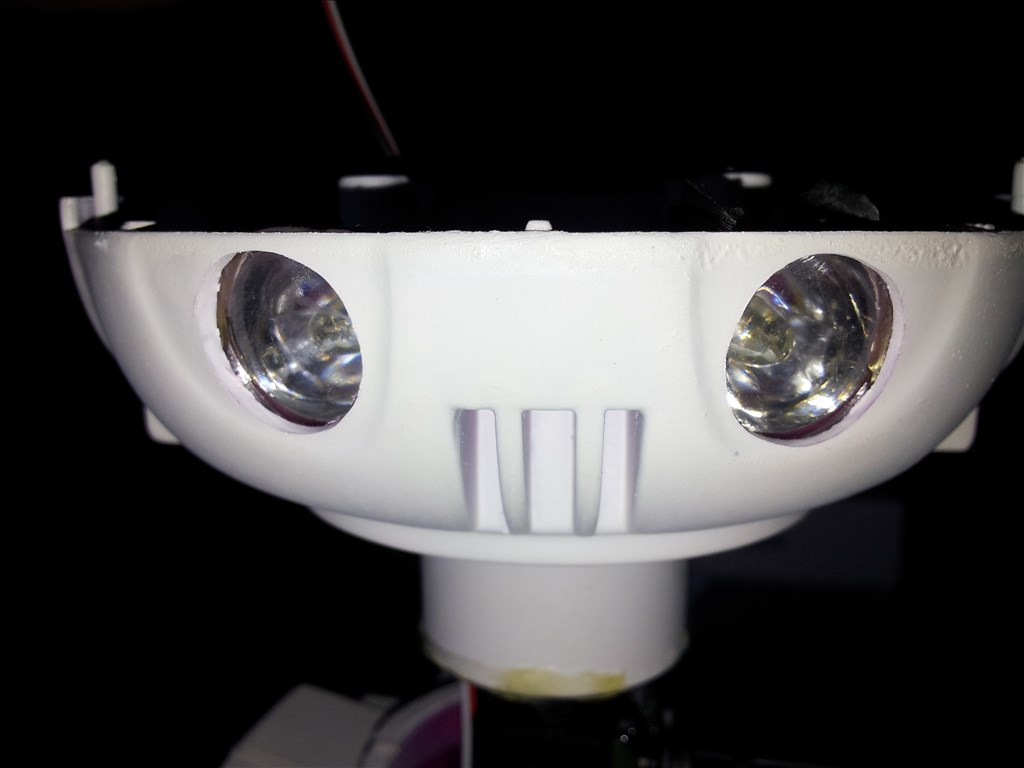
the camera is modified to be powered by USB and at least the head is moving
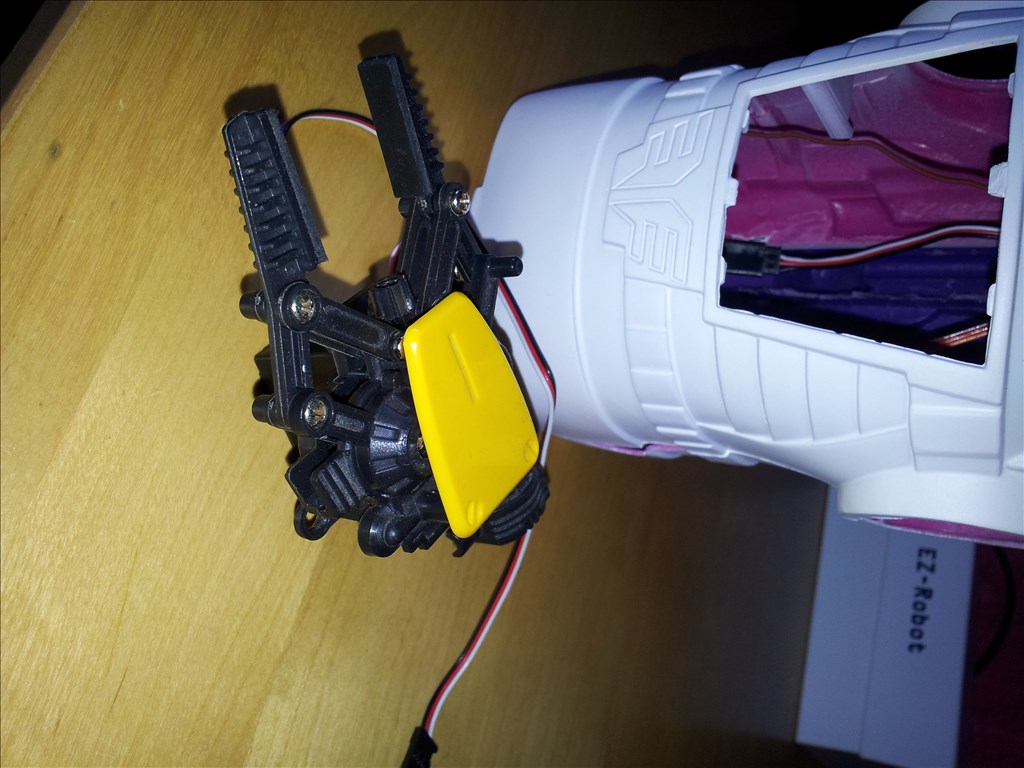
The hand is built out of a OWI-robot-arm and connected with a servo. Next step will be the arms. Until now I´m not sure which feet it will get.
Greetings from the bavarian-wood.
PS: sorry for my bad english tired

By HablijacK
— Last update

Discover more robots
Redzone's Inmoov With A Slight Modification
Animate an Inmoov robot with EZB4 scripting, expanding servo control with EZB3 compatibility and iterative learning and...
Wiinteru's Blue Irobot Roomba Hack
Hack a blue Roomba using an EZ-B v4 and extension cables; progress made while waiting for correct 7-pin PS2 connectors.
Rickymahk2013's Mark 1 Robot
Develop robots with Synthiam, build the Mark 1 DIY robot, publish a DIY book and showcase projects at international...

Your Marvin robot looks awersome if you are still in the process of building Marvin keep up the awersome work


Here we go,
long time ago, in bavaria far far away ... Marvin has to wait for a long time, but now i can continue my work.
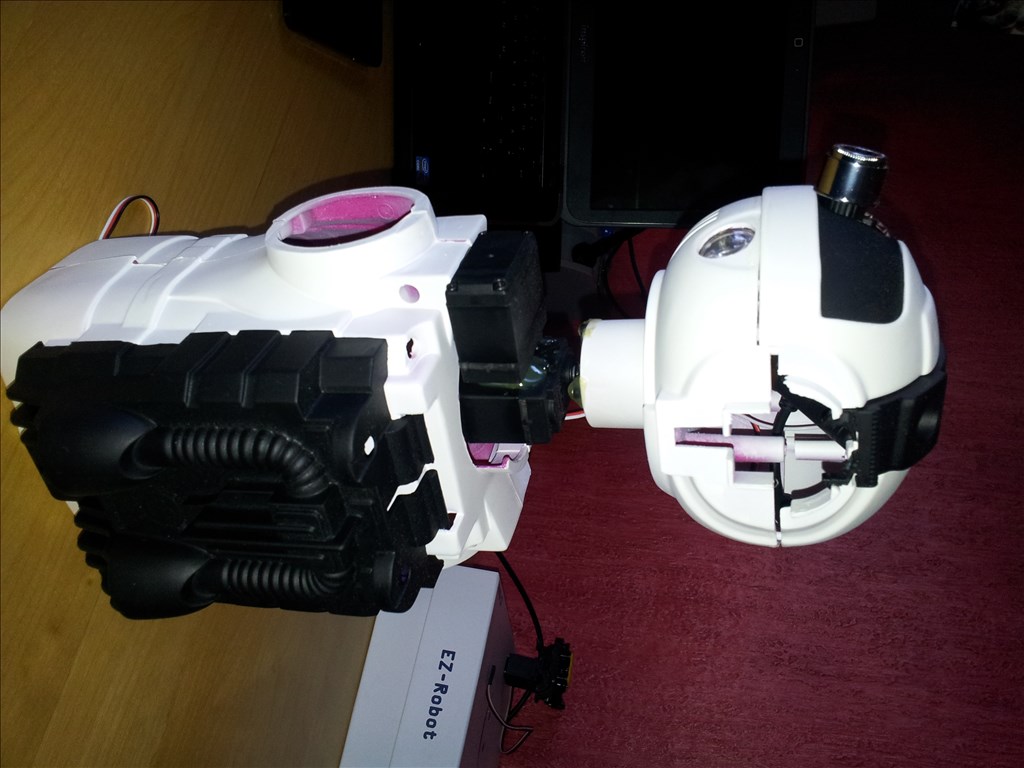
Shoulders were mounted provisorily to test the functionality and the look. A rover base completes the black and white look (looks like i have to raise the body a bit so that the proportion of the body and the rover fit each other)
The battery pack was mounted in the black jet-pack on the backside.
Here is a small video of his previous functions:
I love the Rover 5 base by DAGU
It gives it a awesome look.
That is a delightful robot. Keep up the good work.
:D