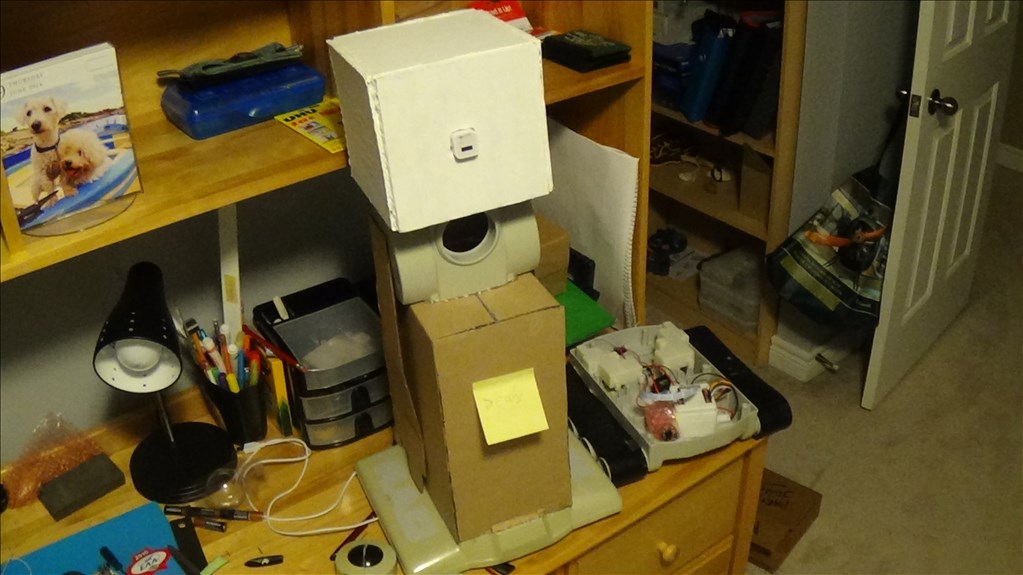
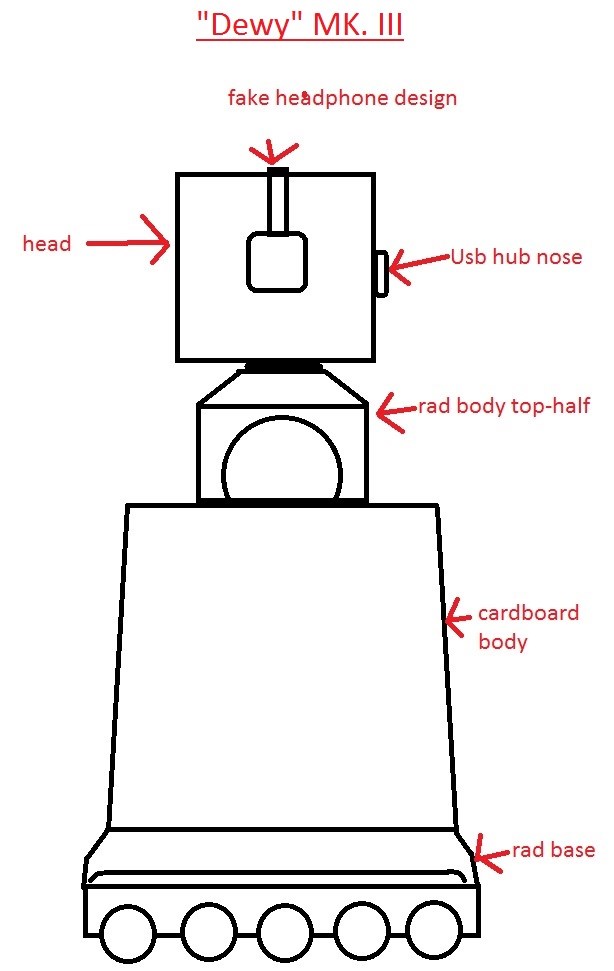

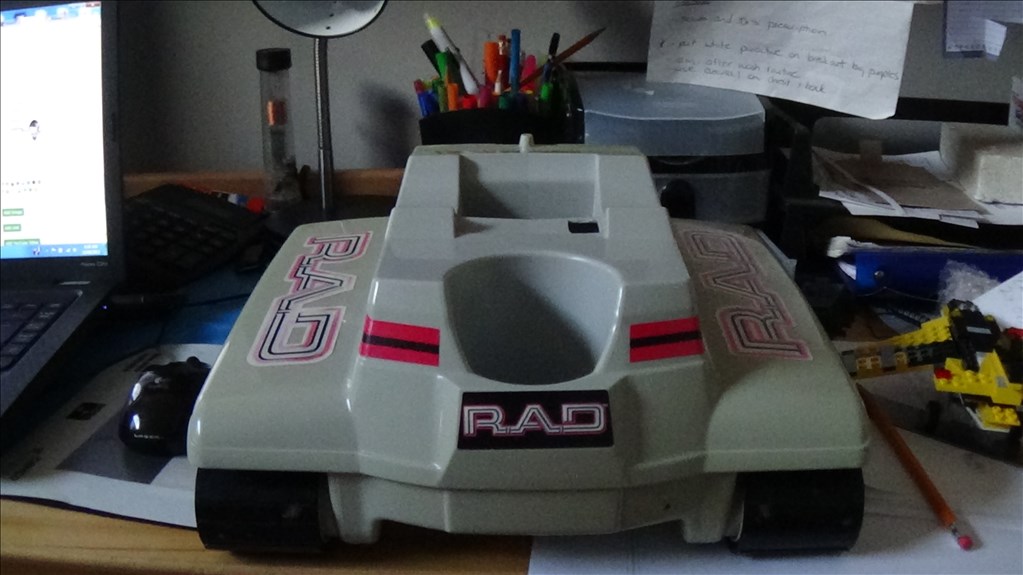
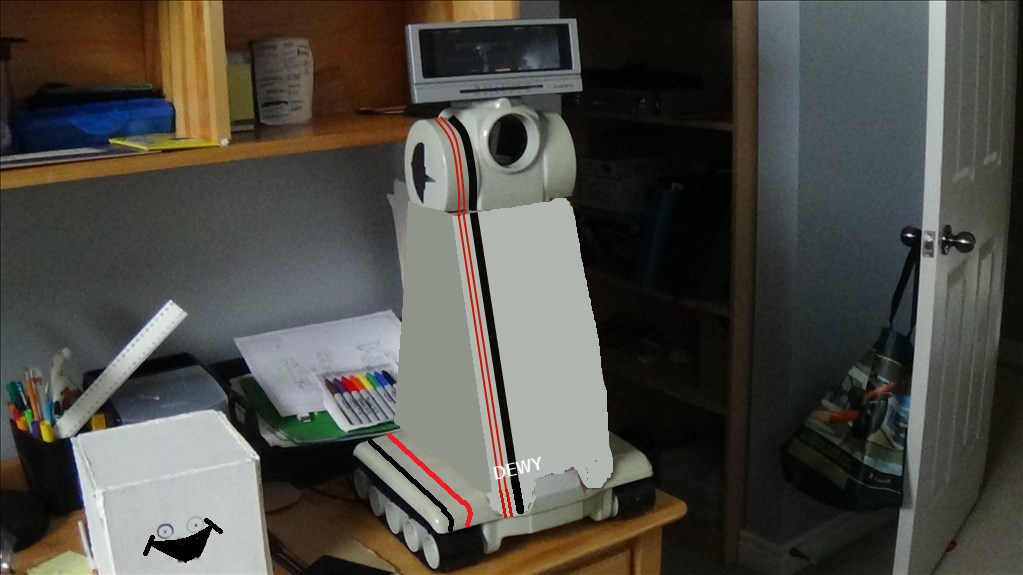
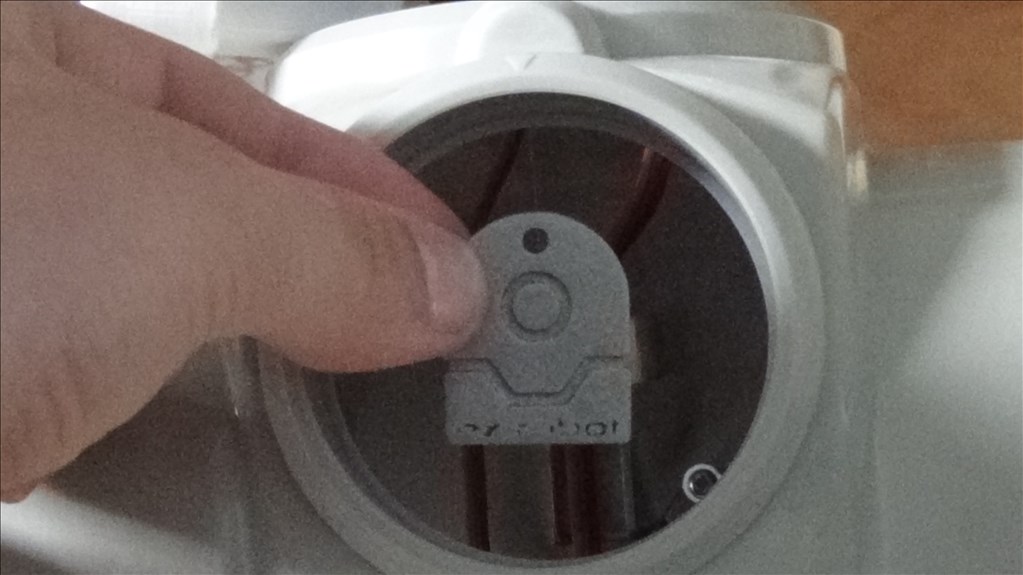
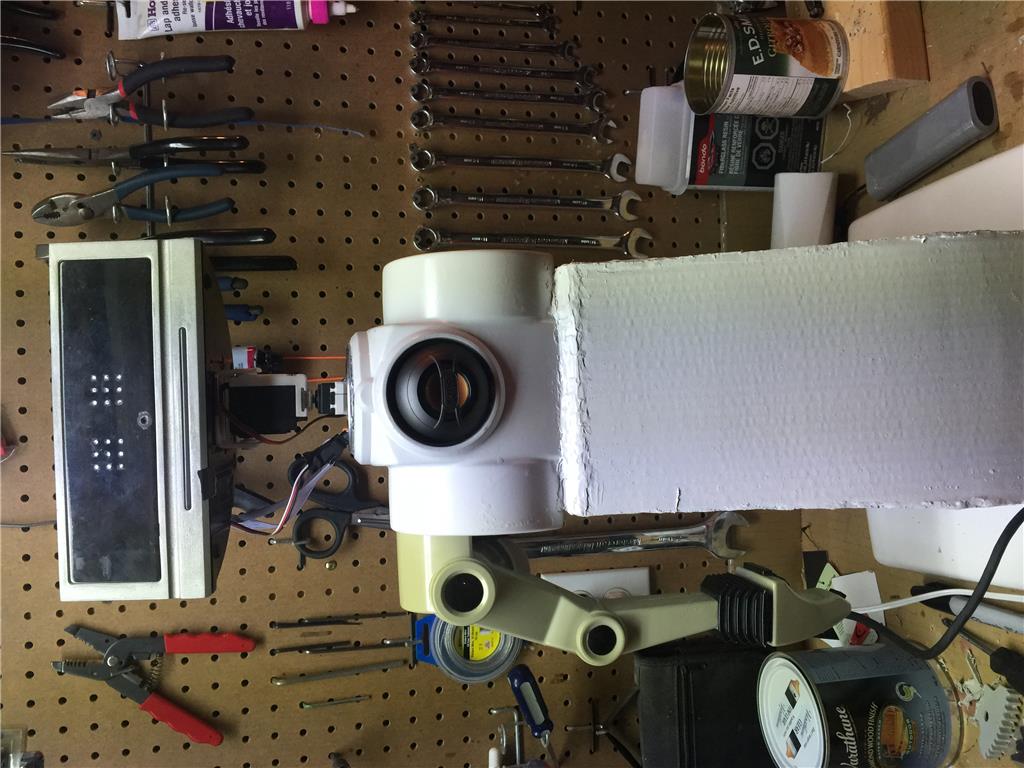
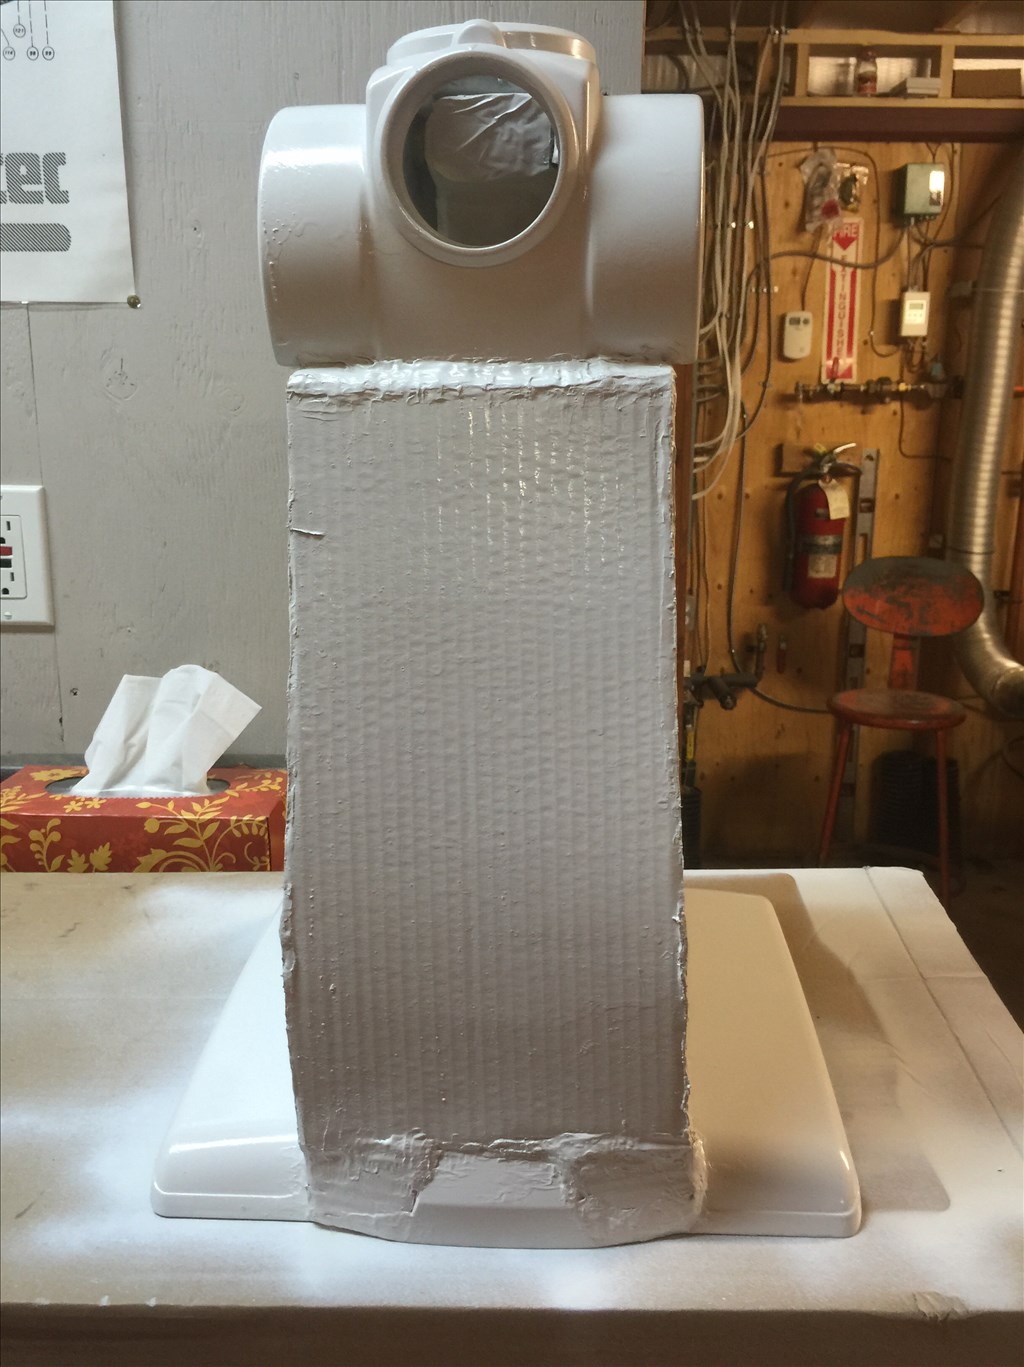
This is the thread for my current project Dewy. He is a tall robot that uses RAD parts and models a omnibot in a way.
For showcases sake:
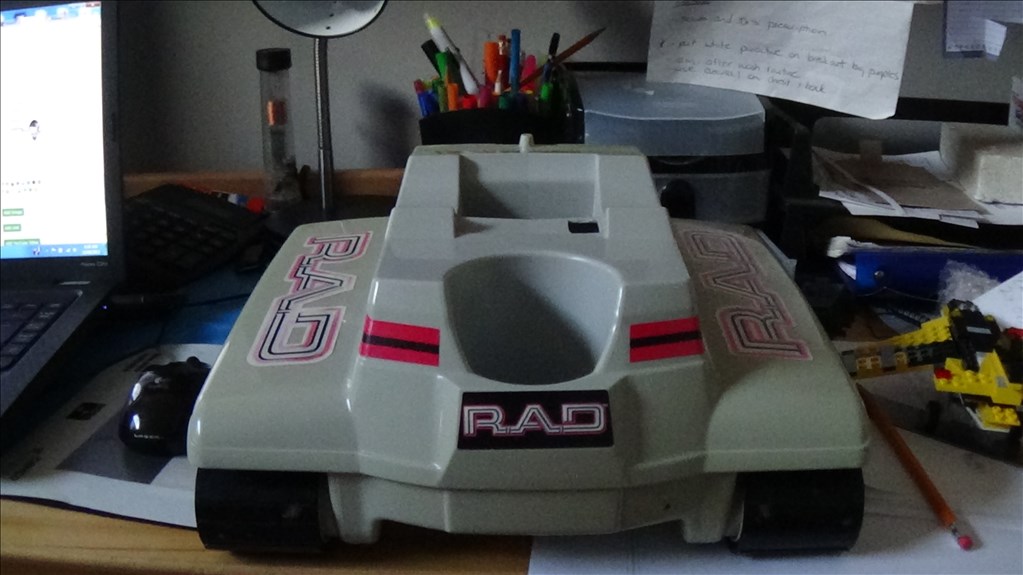
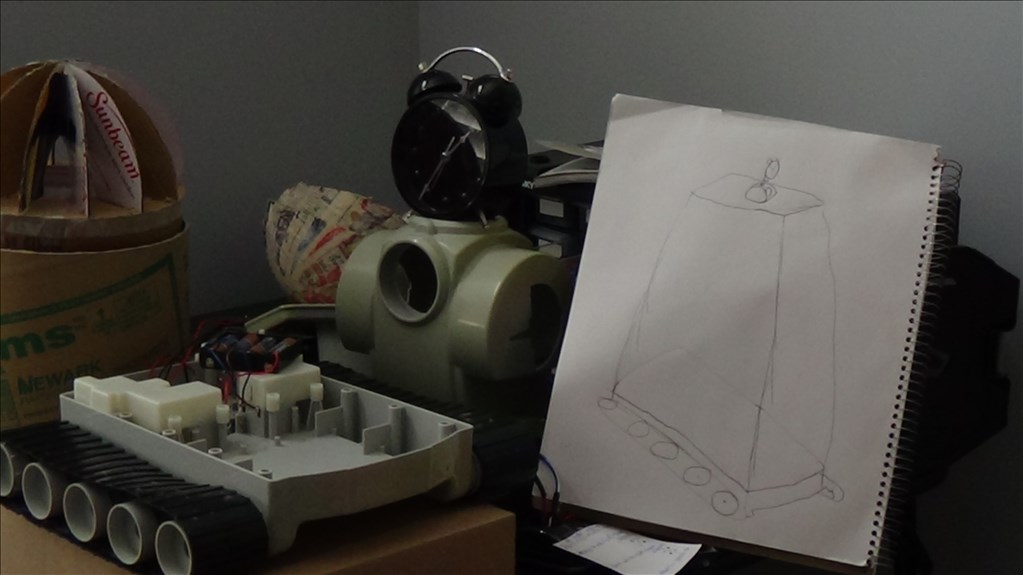
Here's the process of tearing down the RAD.
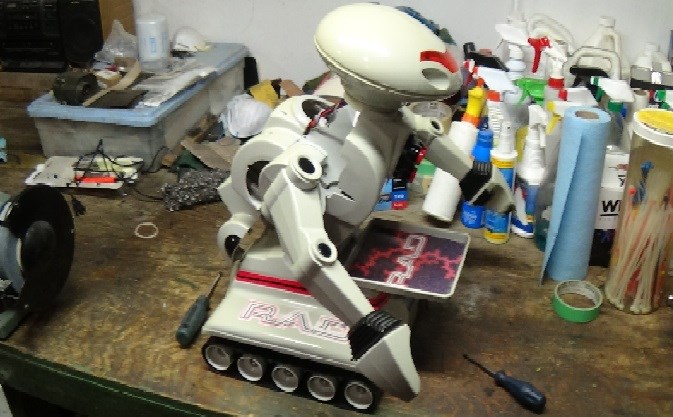
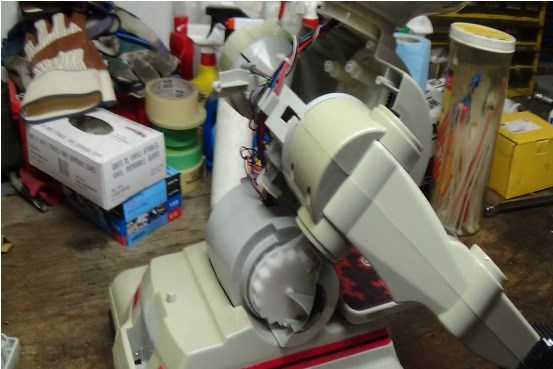
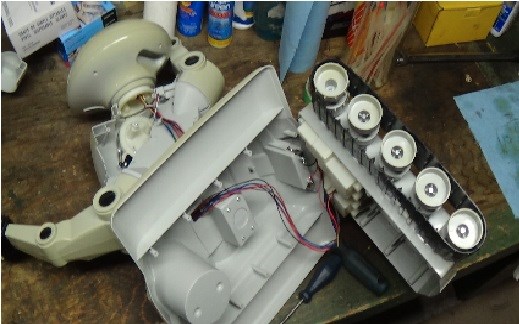
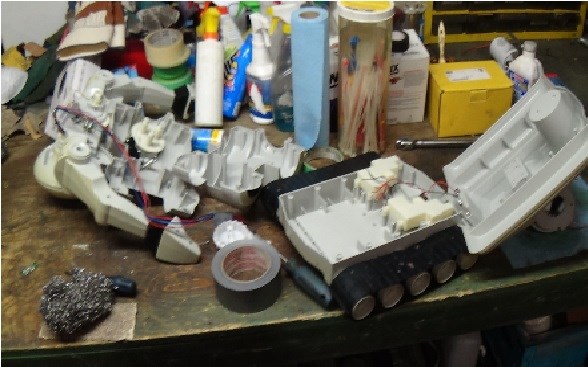
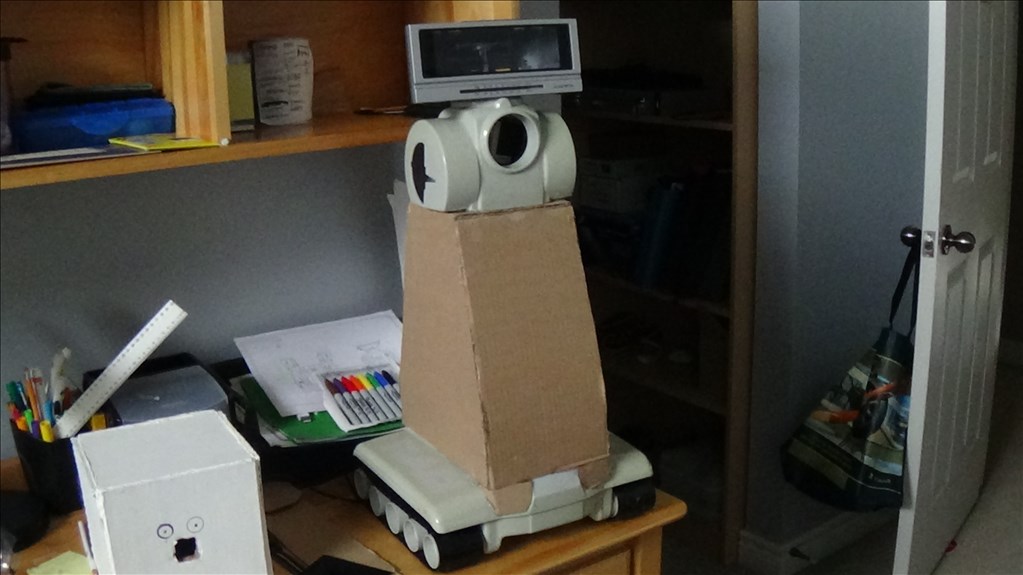
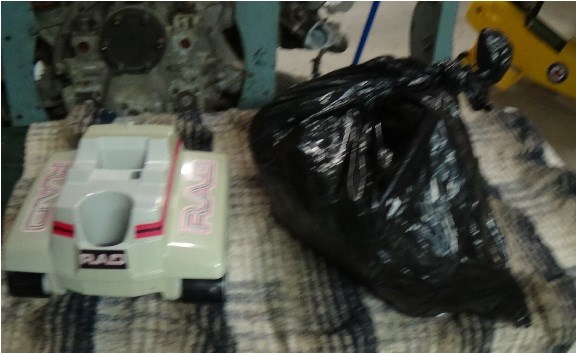
Here's where I finished off.
By CardboardHacker
— Last update


Discover more robots
Steve's Introducing Vic The Vac
Victor Vac: Roomba-based EZ-Robot with EZ-B v4, sensors and Synthiam ARC scripting for autonomous vacuuming, voice,...
Sweetn8's Teddy Ruxpin And Grubby
Restore Teddy Ruxpin and Grubby with EZ-B v4: lip-sync speech, eye/mouth/head motion, mobile wheelchair/roller-skates,...
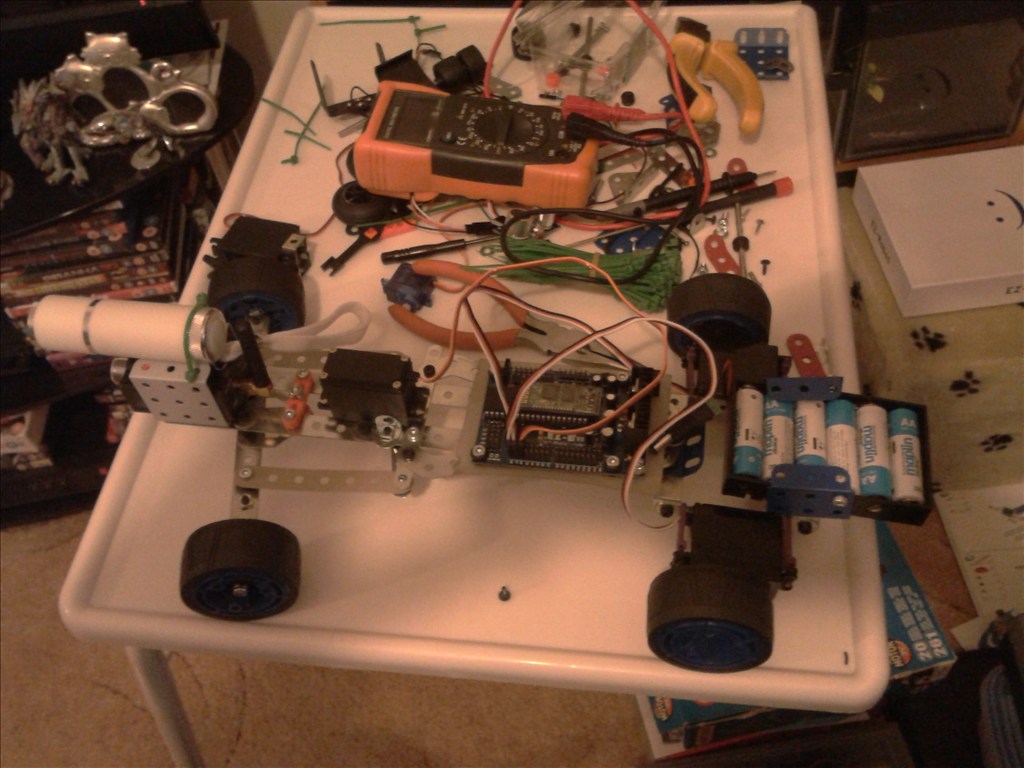
Billderwent's Boris!
EzB robot built from Meccano parts, servos, cable ties and torch-mounted camera, with steering linkages,...

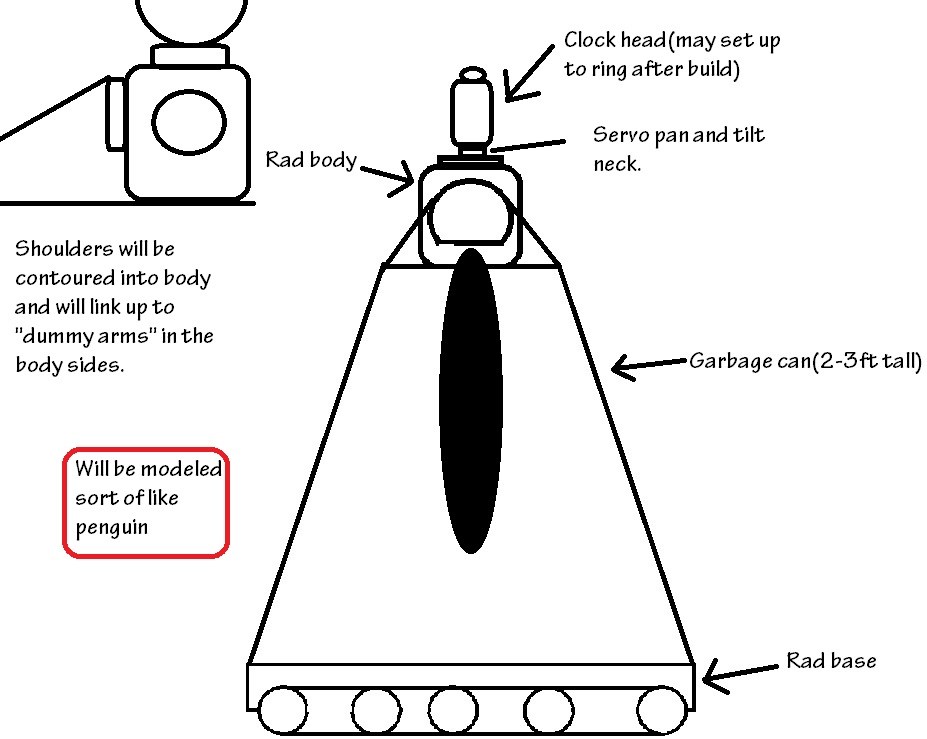
I have revised the design based on designs i made in the "penguin-like robot" thread. I figured I would post once more in that thread. It was a lost cause.
Anyways here's the current design:
hi here a link for all kinds off motor mounting.
motor mounting
Here's what I got done today. (No...,Seriously)
Looks like it's going to turn out great
great start
Nice
It's good to see Dewy coming together.
Ok so demonstrated the bottom part of dewy at school today and the younger children loved him! He is pretty loud though! working on the neck tonight and hope to have him looking around soon.