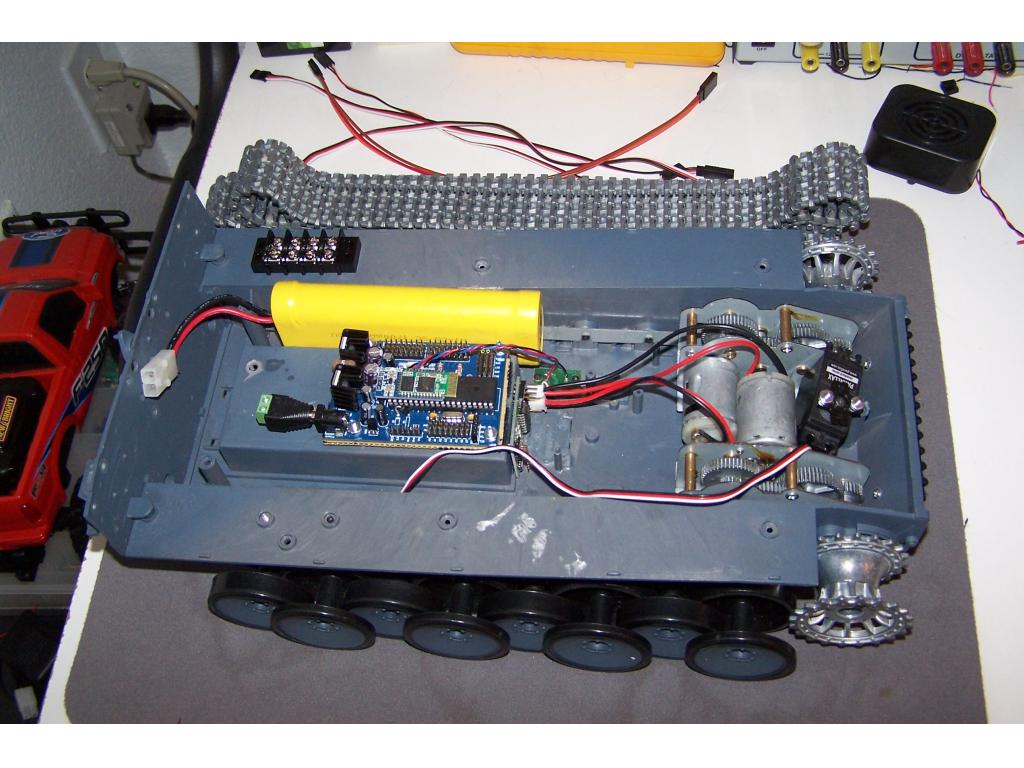
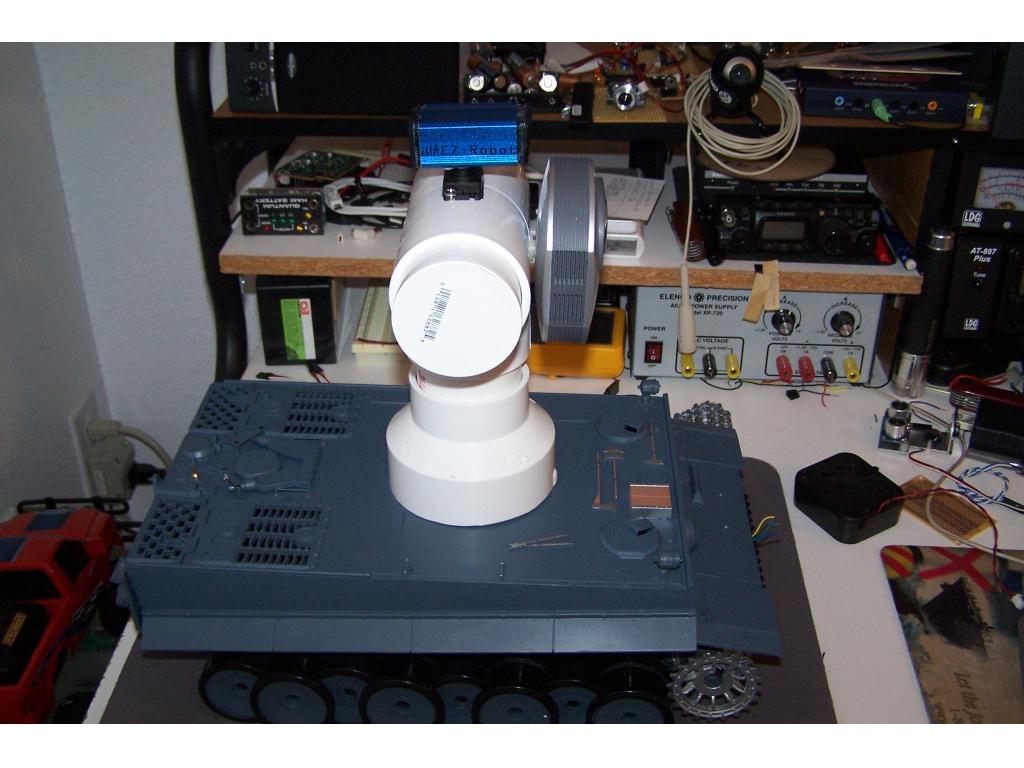
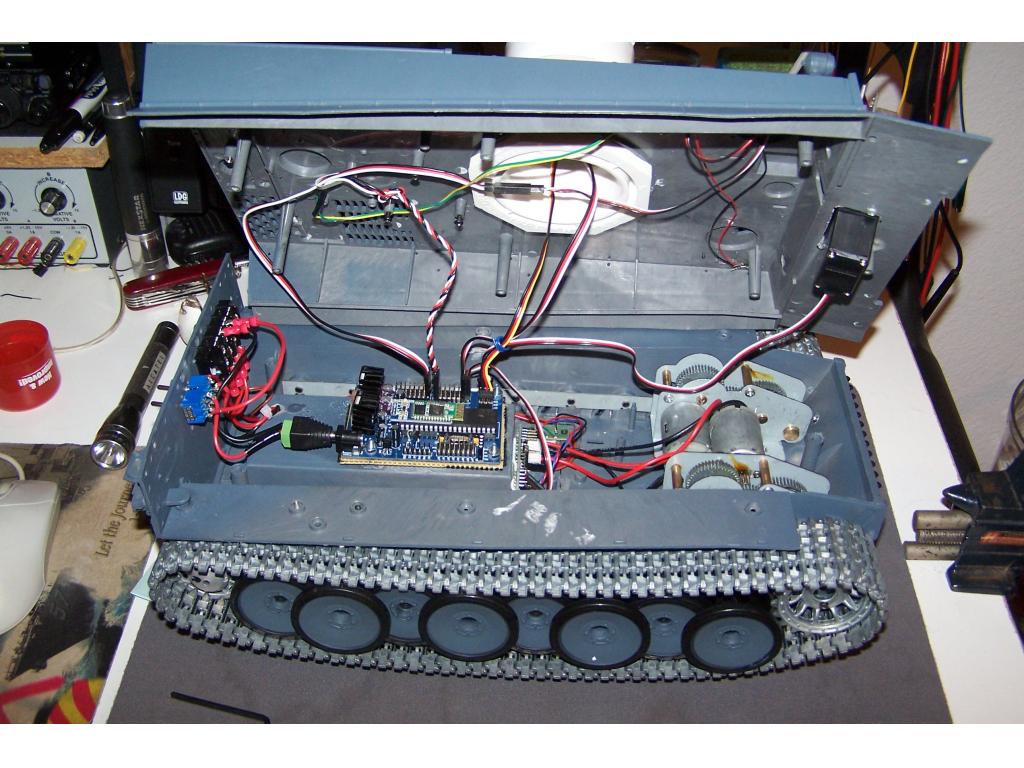
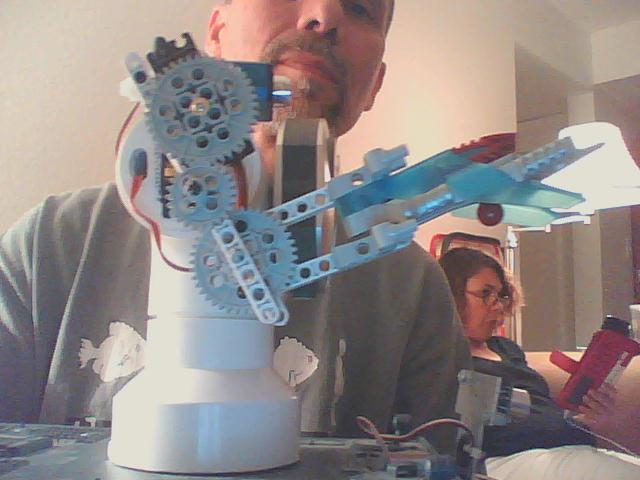
I don't know if this will work, but here is a youtube link. This was my first attempt at uploading a video there. The file was done on an Galaxy Tablet, at 122 MB, I figured DJ would prefer it not take up space on his server.
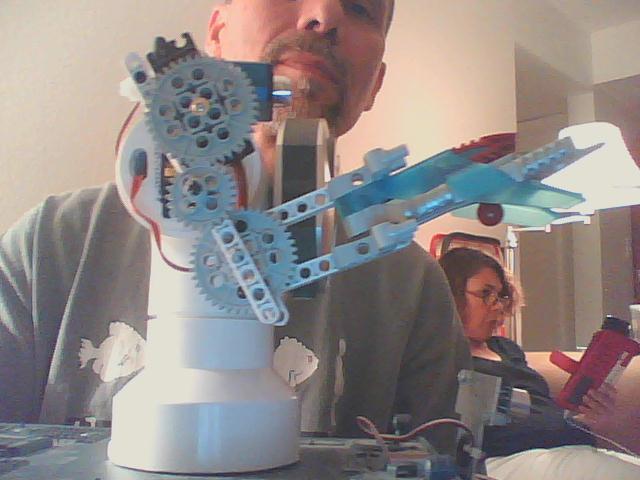
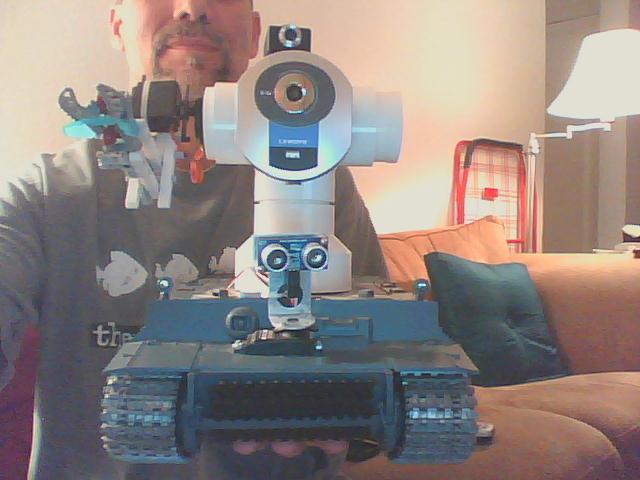
Dogbot has a bit of User operator error, but with a little more training It'll be run much soother. Next phase is to pickup a few more Servos to add a better head, and a left arm. At somepoint the wife (our resident knitter) will make a red sweater for the dog, so DogBot can track her. Given the reliablity issues involved with color tracking though, I'm leaning more toward RFID tracking.
By Dave L
— Last update

Discover more robots
Sfoy's My Frankenbot - Robosapien, Hearoid, Ottobot Head
Build a custom hearoid omni bot base with mini-ITX, acrylic enclosure, IR sensors, cameras, pan/tilt, EZ-B integration...
Jstarne1's Meet Rc-Xd Airsoft Droid Dual Wield Gunner...
RC-xd Airsoft Droid: modified Omnibot on a rad 2.0 base with dual automatic airsoft guns and EZ Cam for Mech Wars, built...
Luis's Dt Ezb Weather For Weather Underground Api
Control EZ-B robots with a Weather Underground API handler: fetch forecasts, speak templates, map variables, and run...

Sounds like he has a lot of power. Great job!!
Dave, press CONFIG in the Sabertooth Movement Panel and change the values to the speed you desire
Nice work Dave - I wish I had treads like yours - did you build them yourself or get them fom a kit ?
@Hazbot
they look like a tiger tank kit chassis .I used to have one a few years back.
DJ, I got that part worked out changing the values. I was hoping there was a way to change the speed on the fly.
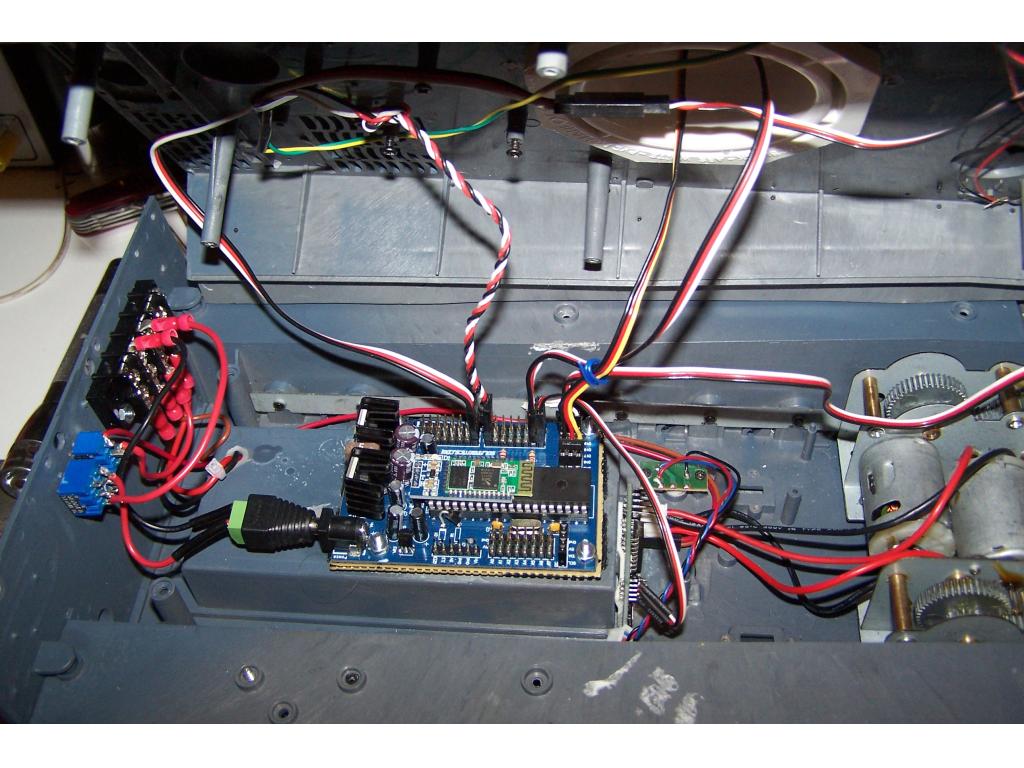
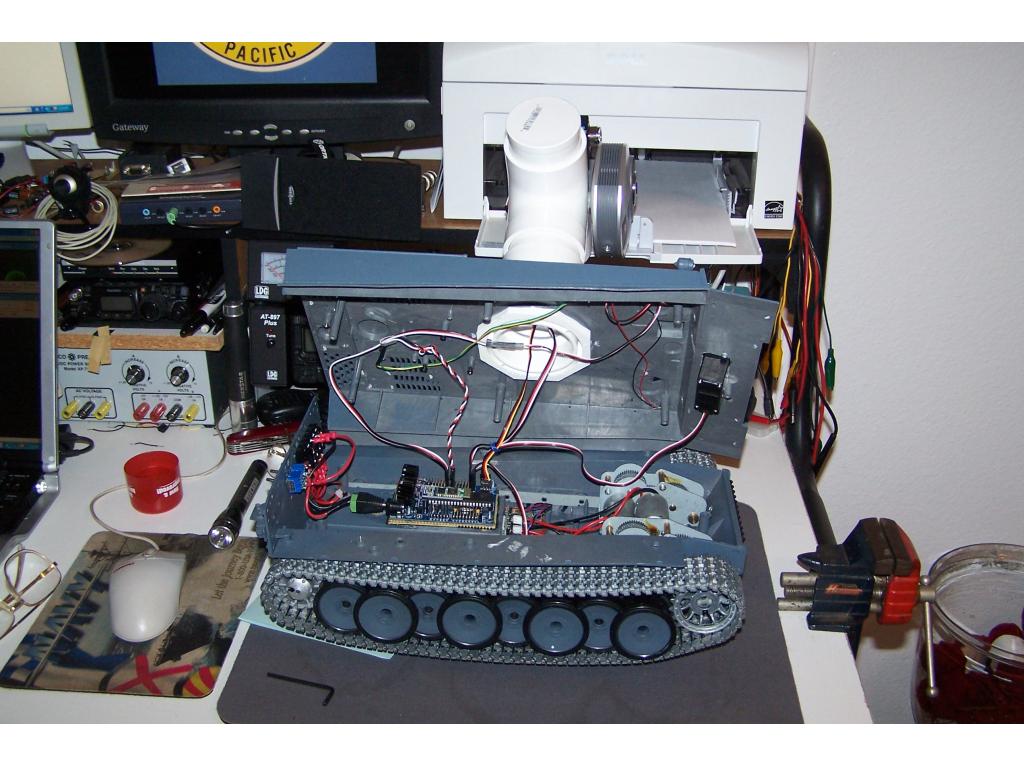
Steve is correct the base and tracks are from a Recycled R/C Tiger tank.
Oops clicked on the wrong Pic.