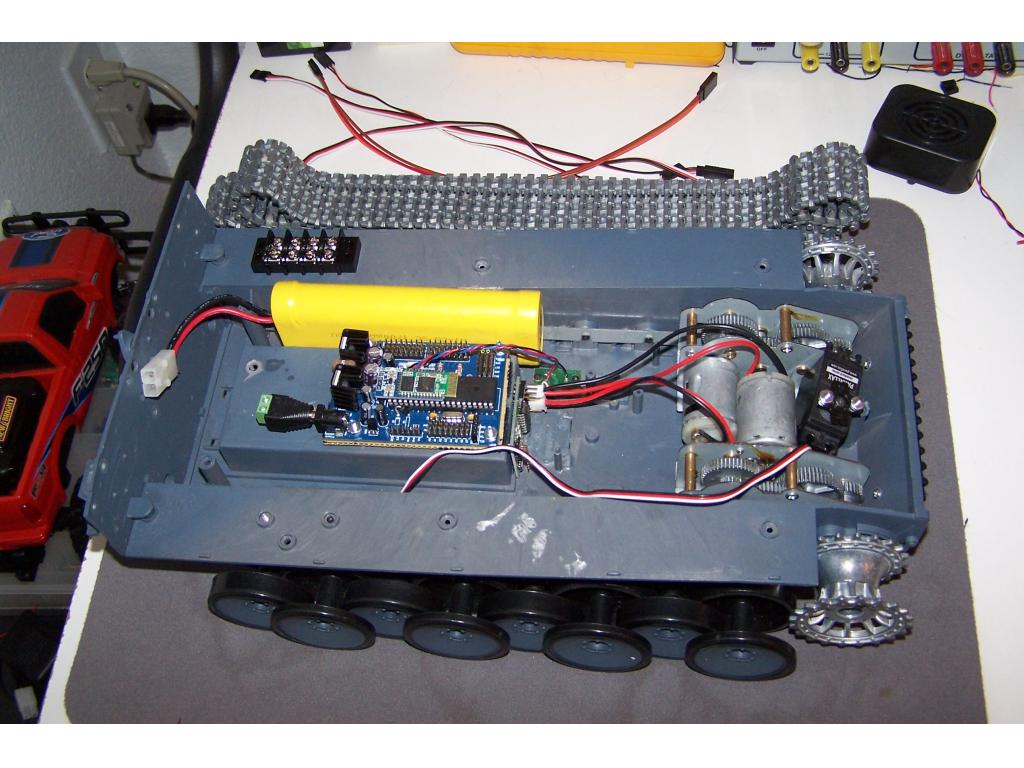
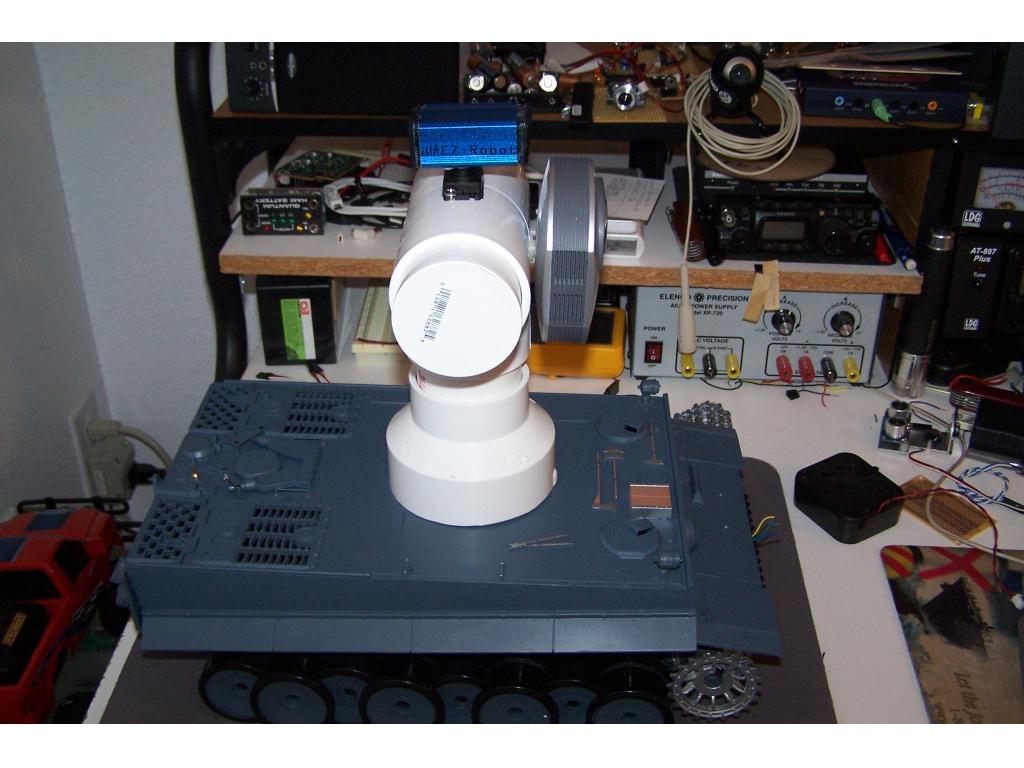
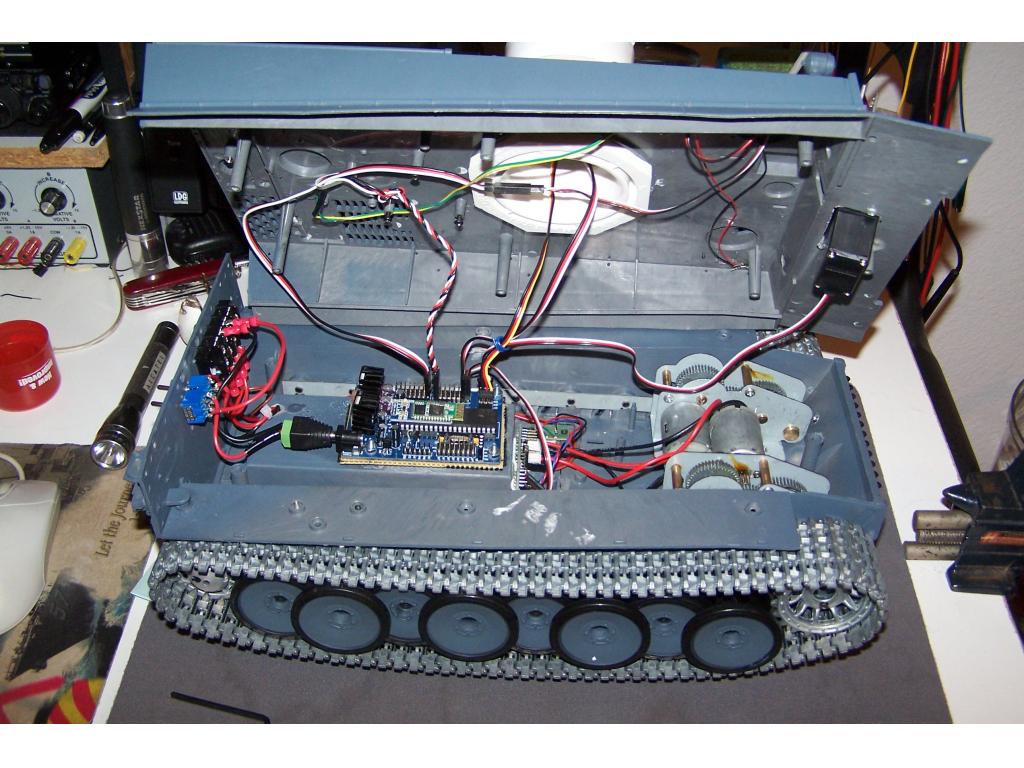
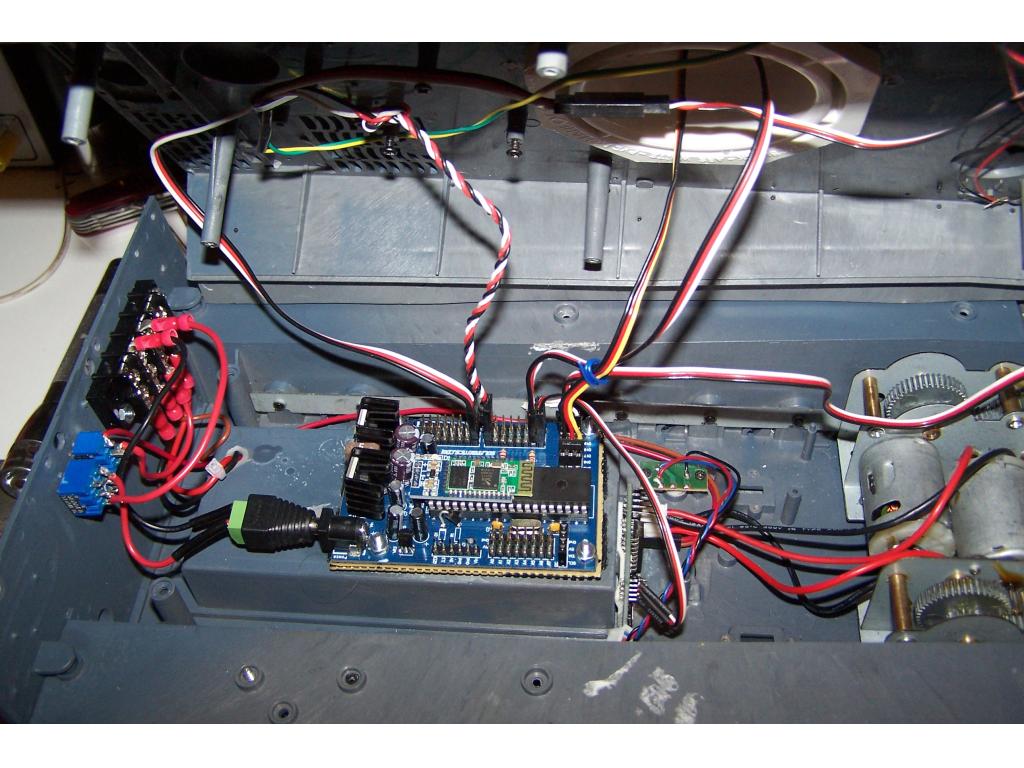
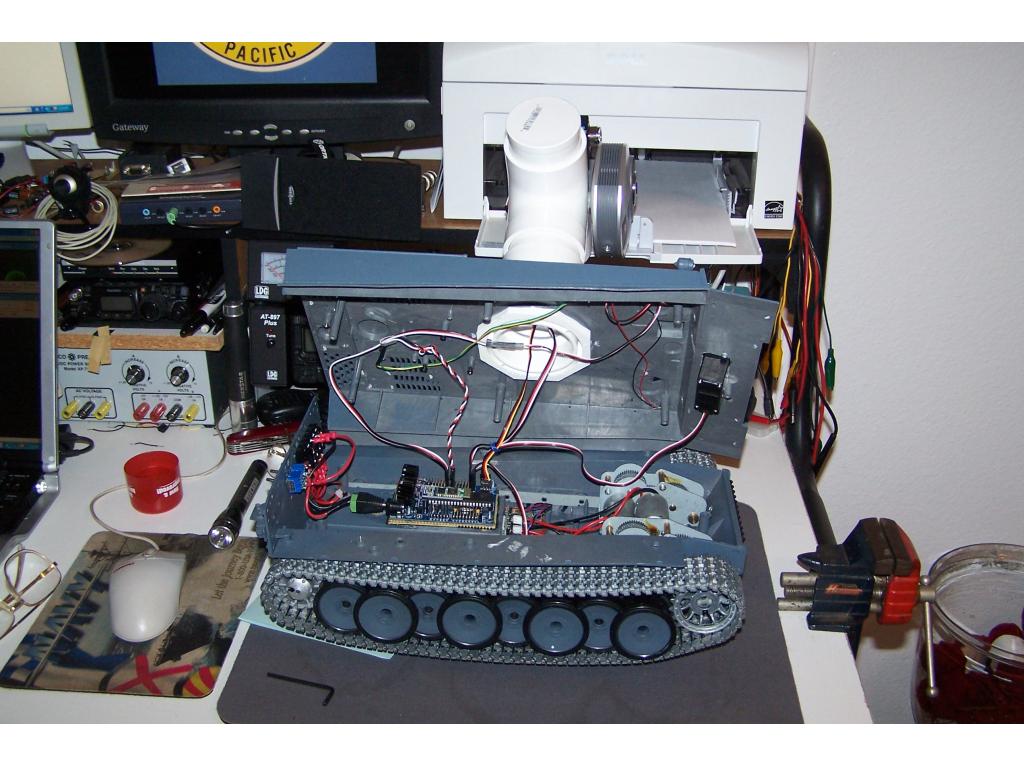
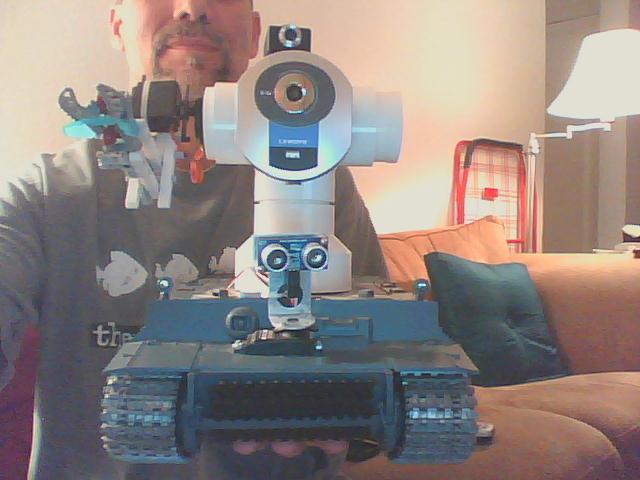
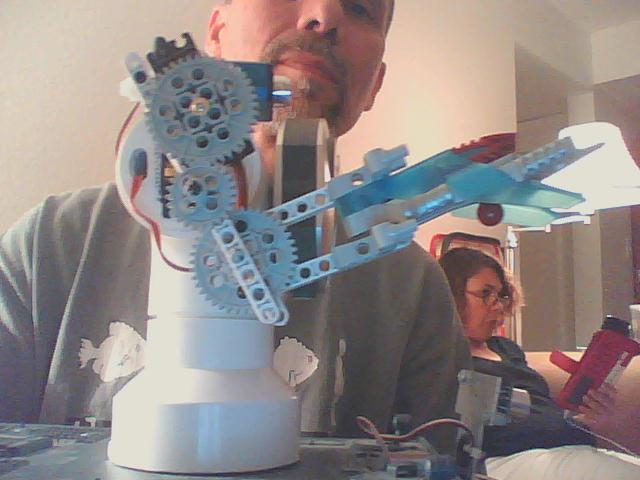
I don't know if this will work, but here is a youtube link. This was my first attempt at uploading a video there. The file was done on an Galaxy Tablet, at 122 MB, I figured DJ would prefer it not take up space on his server.
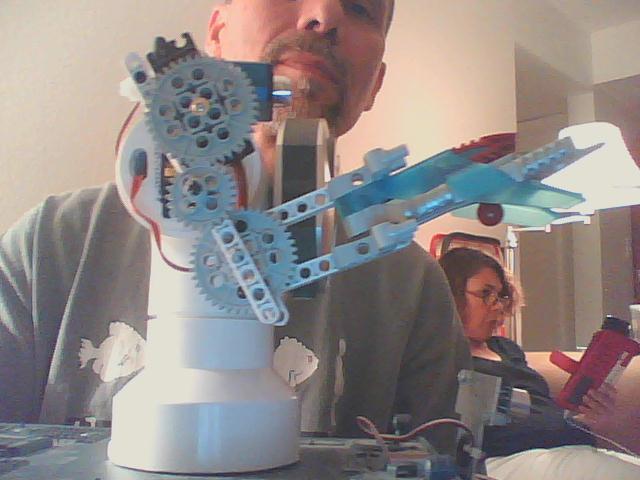
Dogbot has a bit of User operator error, but with a little more training It'll be run much soother. Next phase is to pickup a few more Servos to add a better head, and a left arm. At somepoint the wife (our resident knitter) will make a red sweater for the dog, so DogBot can track her. Given the reliablity issues involved with color tracking though, I'm leaning more toward RFID tracking.
By Dave L
— Last update

Discover more robots
Bhouston's A New Dof For Inmoov's Neck/Head
New InMoov neck mechanism adds an extra degree of freedom, improving head articulation; prototype needs fine-tuning.
Steve's Navigation Test Robot With Intel Realsense T265
Navigate an iRobot Create using Intel RealSense T265 and EZB with Synthiam ARC for reliable visual tracking navigation...
Tameion's Lawrence The Butler
Build Lawrence VIKI/Jarvis-style assistant using EZ-Robot, DJ Sures tutorials and student projects to automate a...

Sounds like he has a lot of power. Great job!!
Dave, press CONFIG in the Sabertooth Movement Panel and change the values to the speed you desire
Nice work Dave - I wish I had treads like yours - did you build them yourself or get them fom a kit ?
@Hazbot
they look like a tiger tank kit chassis .I used to have one a few years back.
DJ, I got that part worked out changing the values. I was hoping there was a way to change the speed on the fly.
Steve is correct the base and tracks are from a Recycled R/C Tiger tank.
Oops clicked on the wrong Pic.