
cE9s4PsOgeBQIORwjd5!~~60_1-634818020230156250.jpg)



Lupuc4g~~60_35-634706297915000000.jpg)


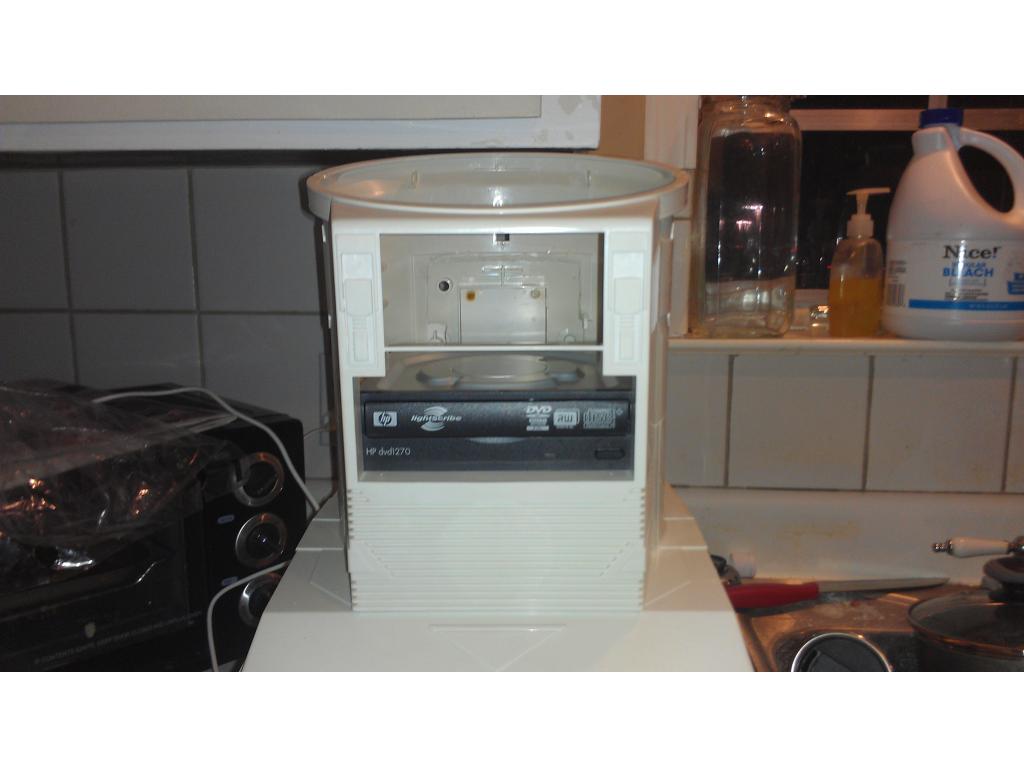
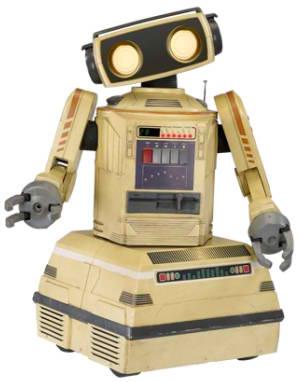
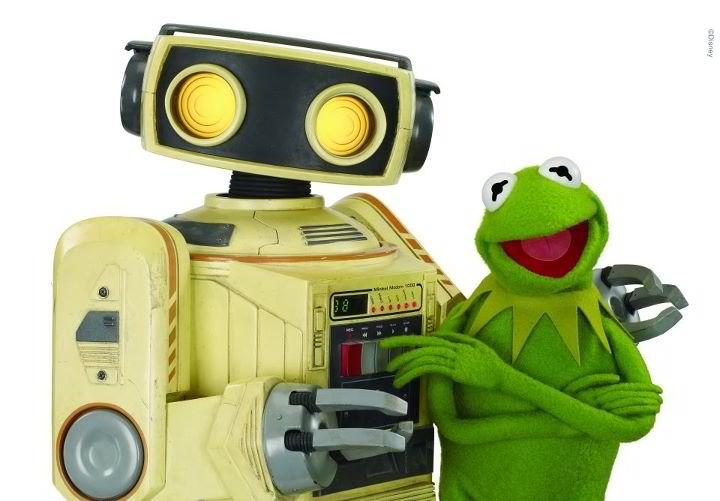
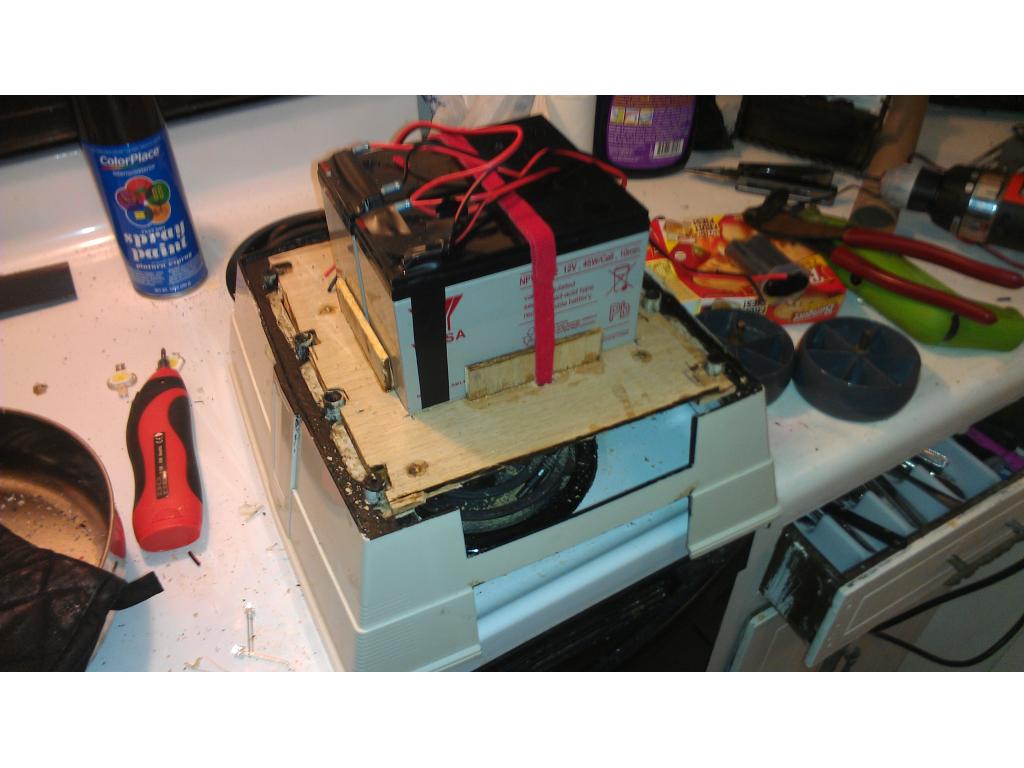

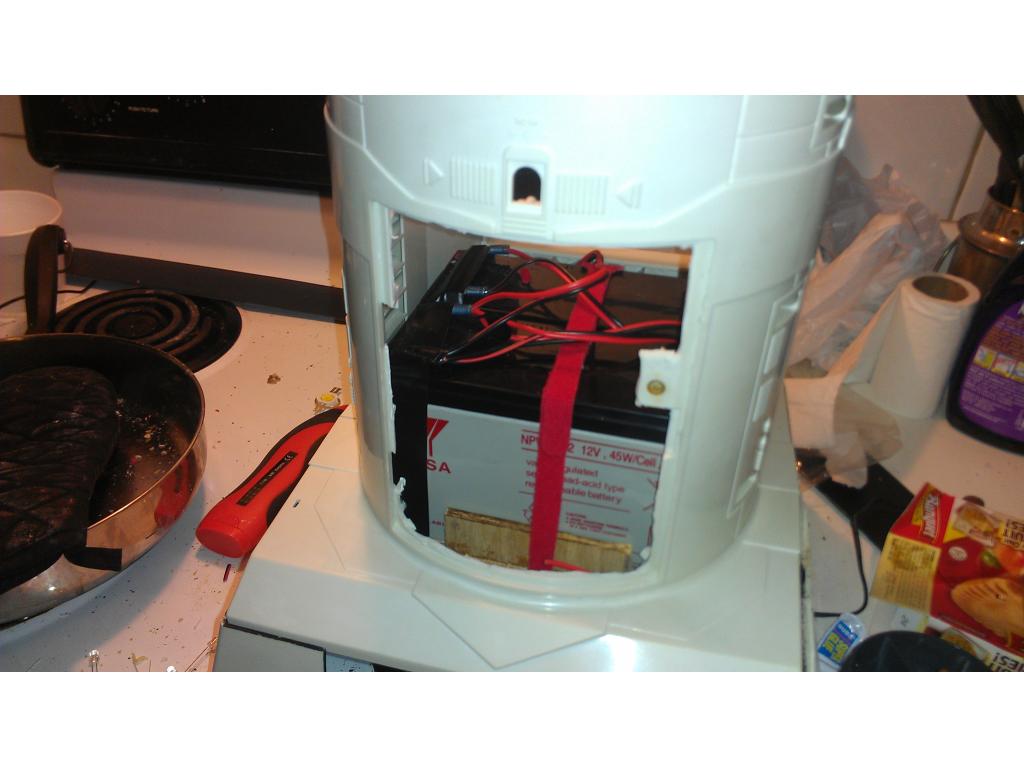
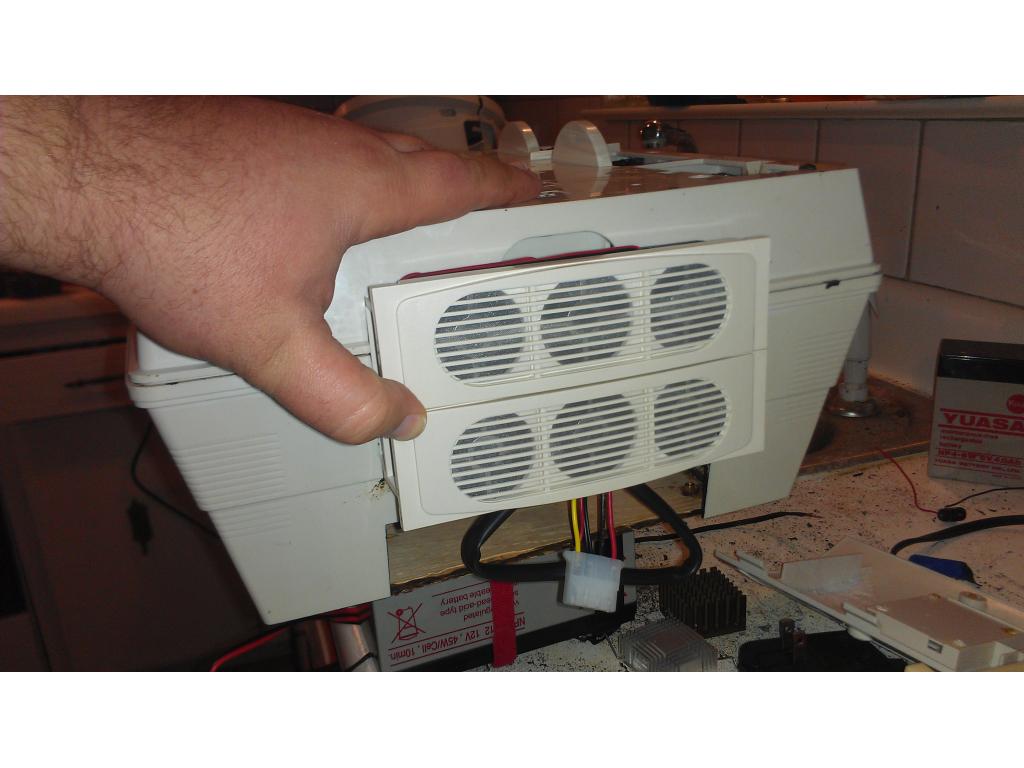
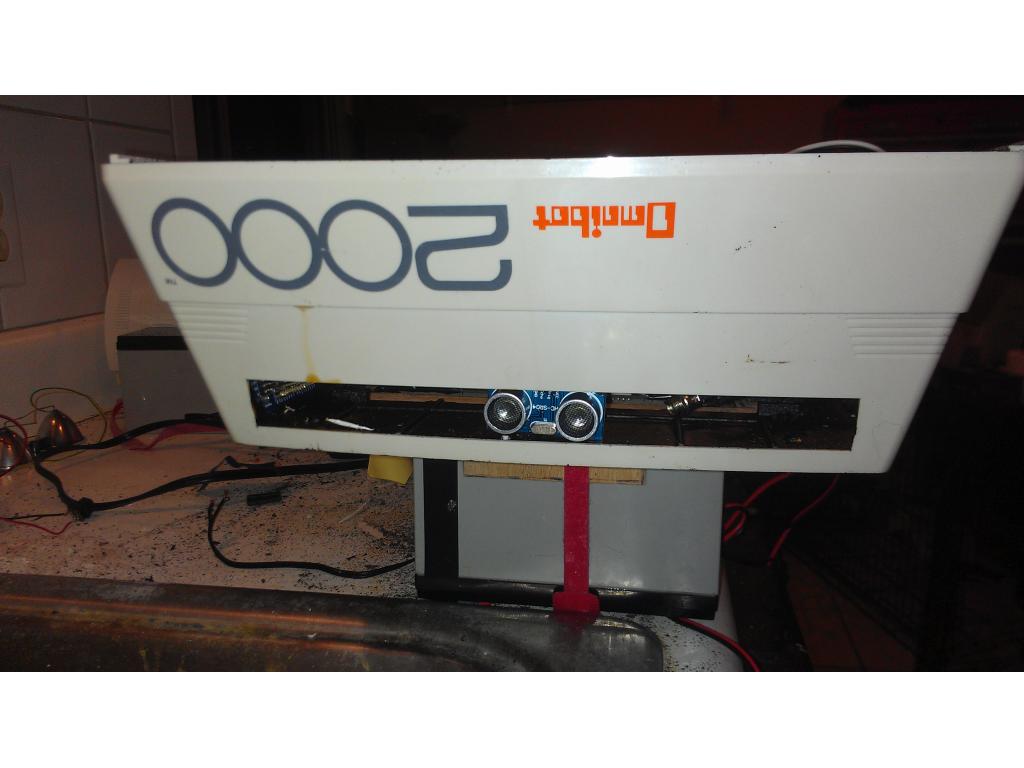
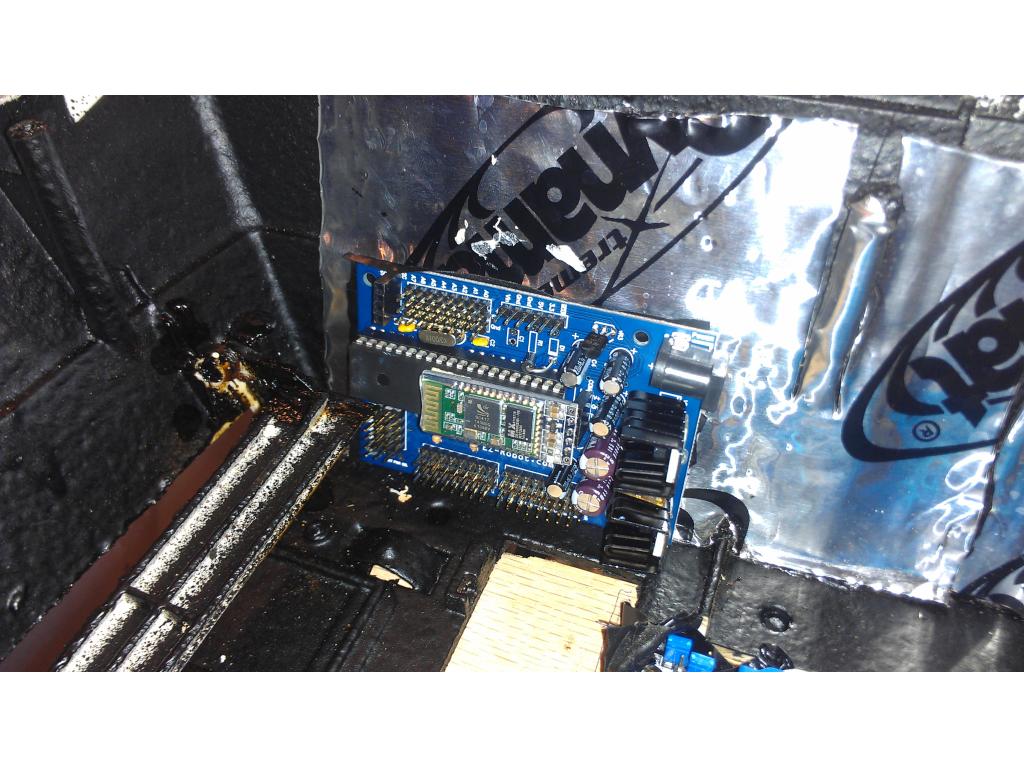
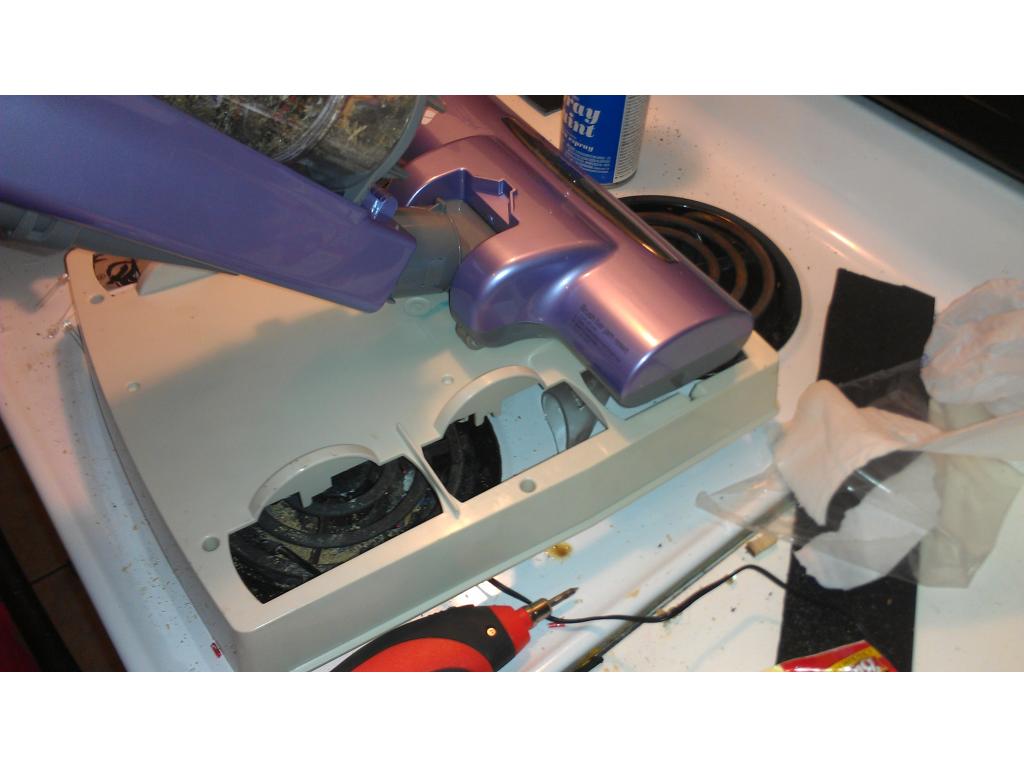

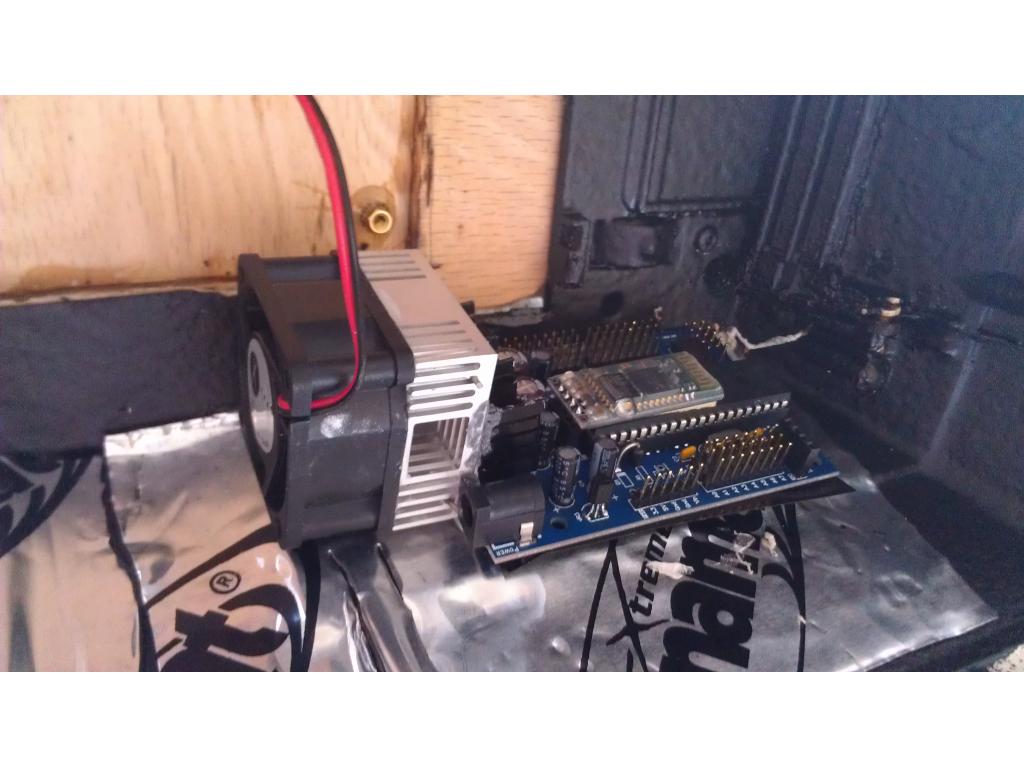
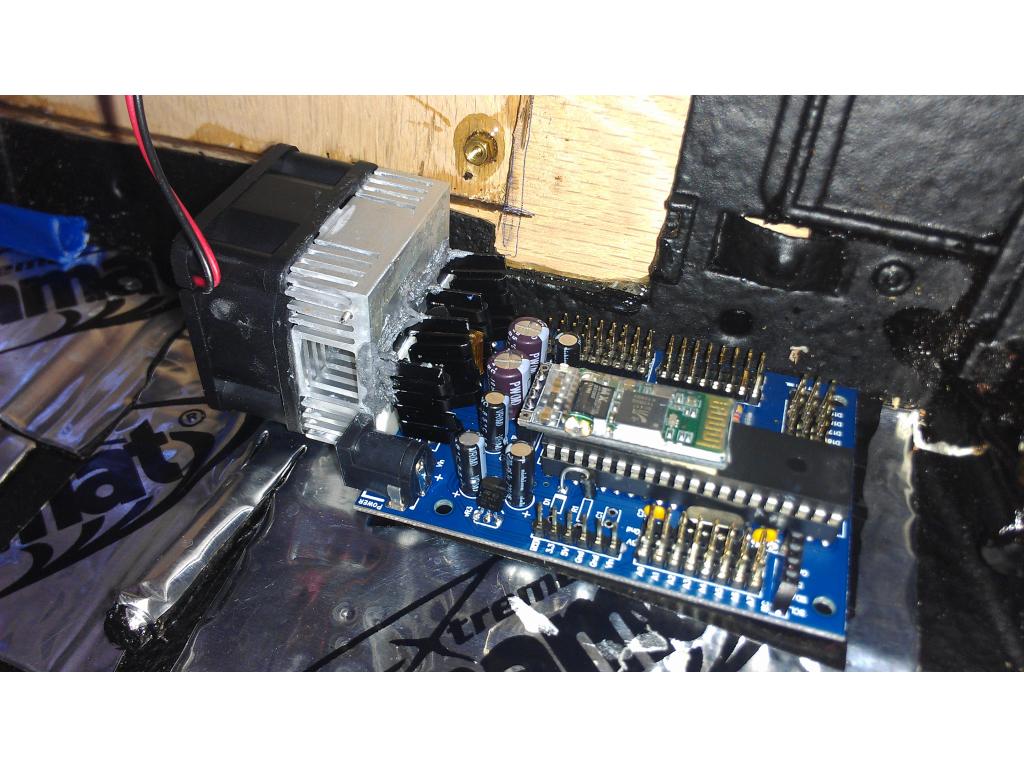

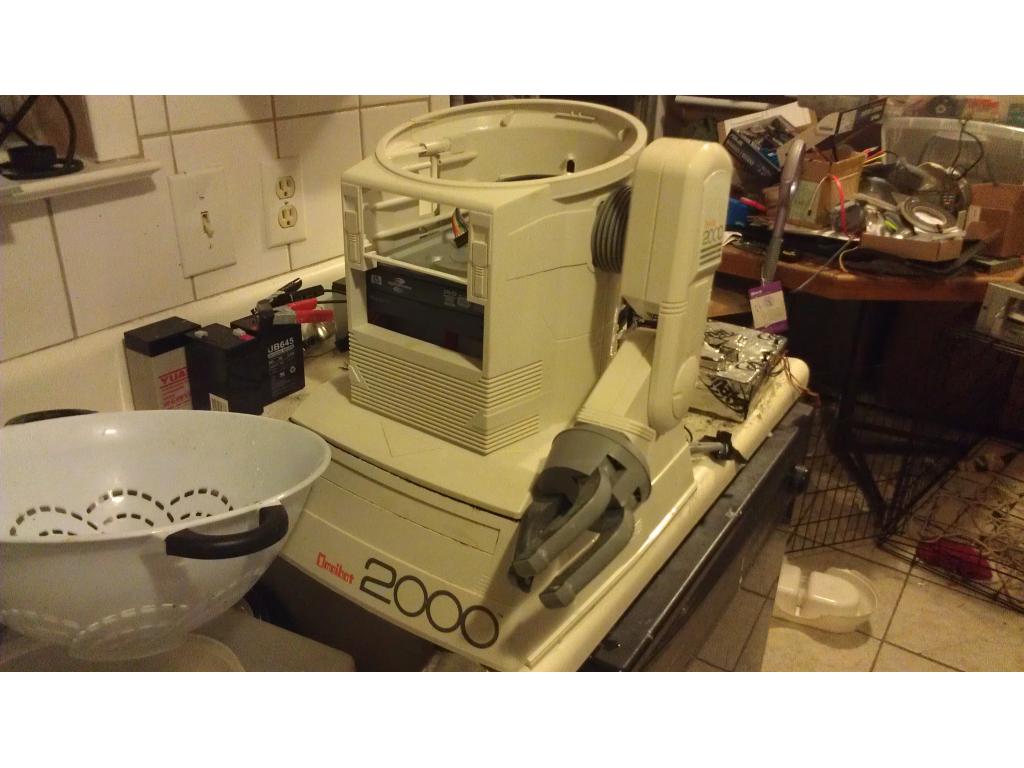
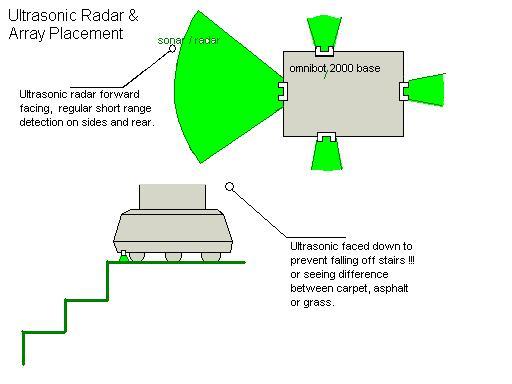
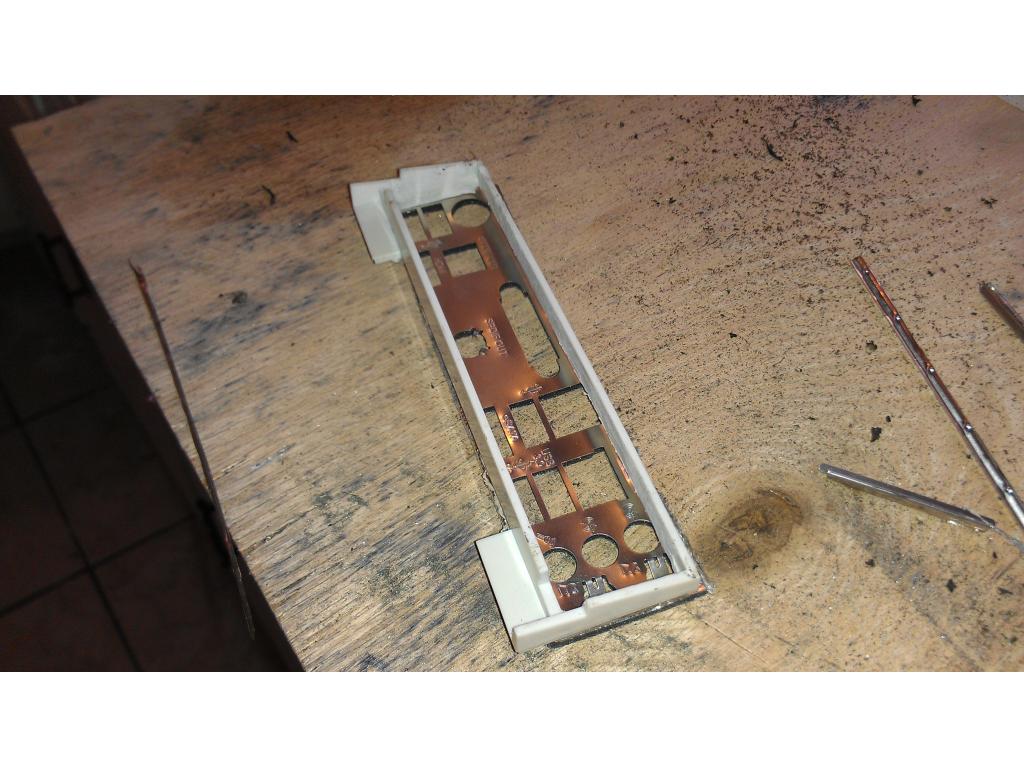
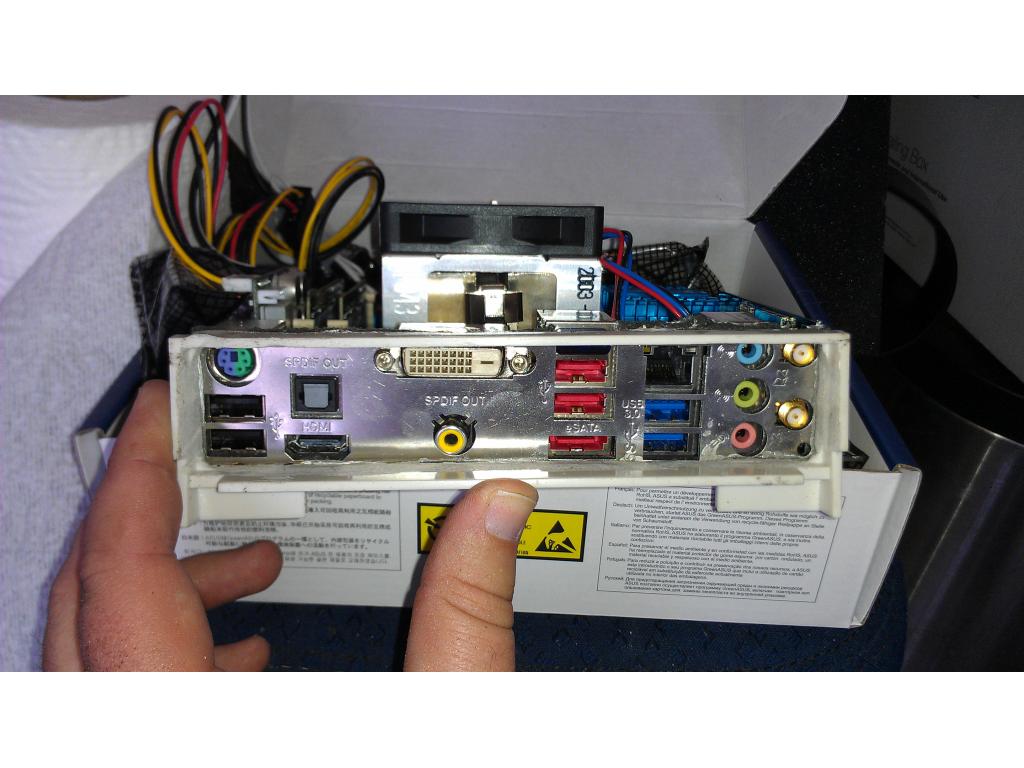
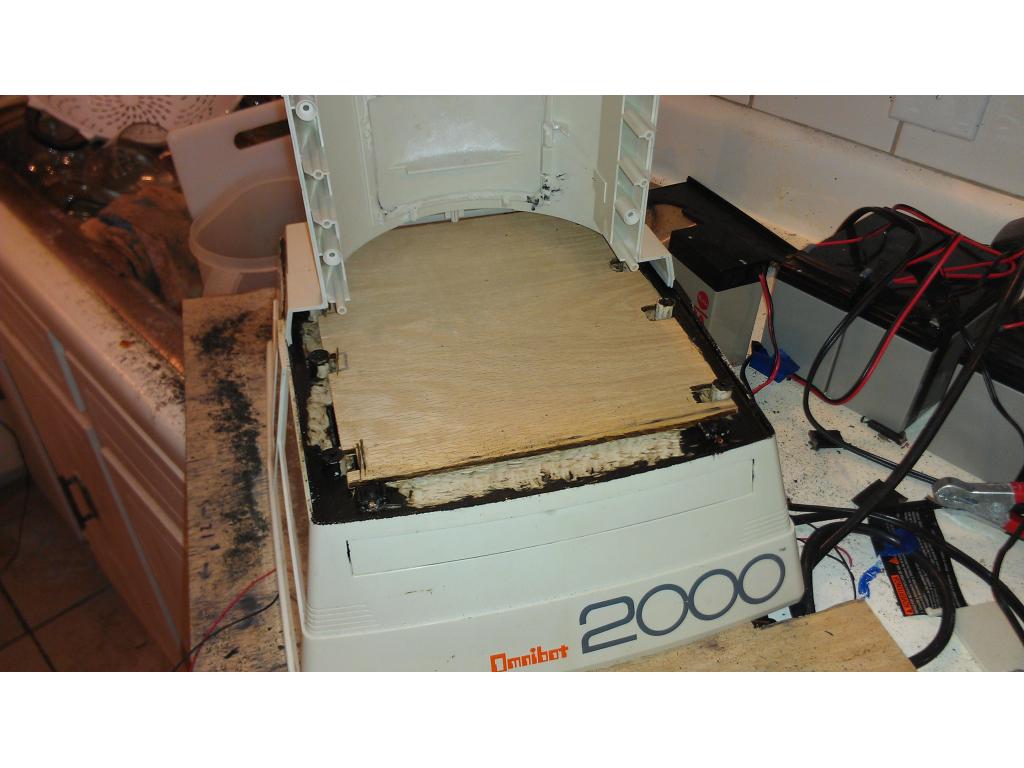
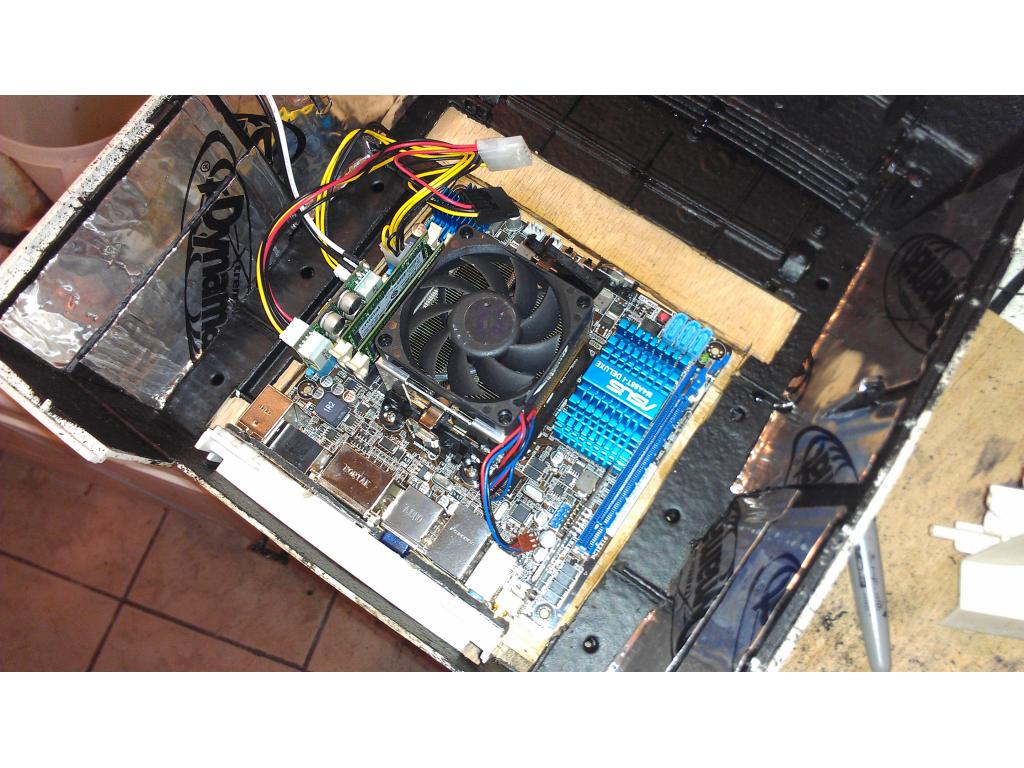
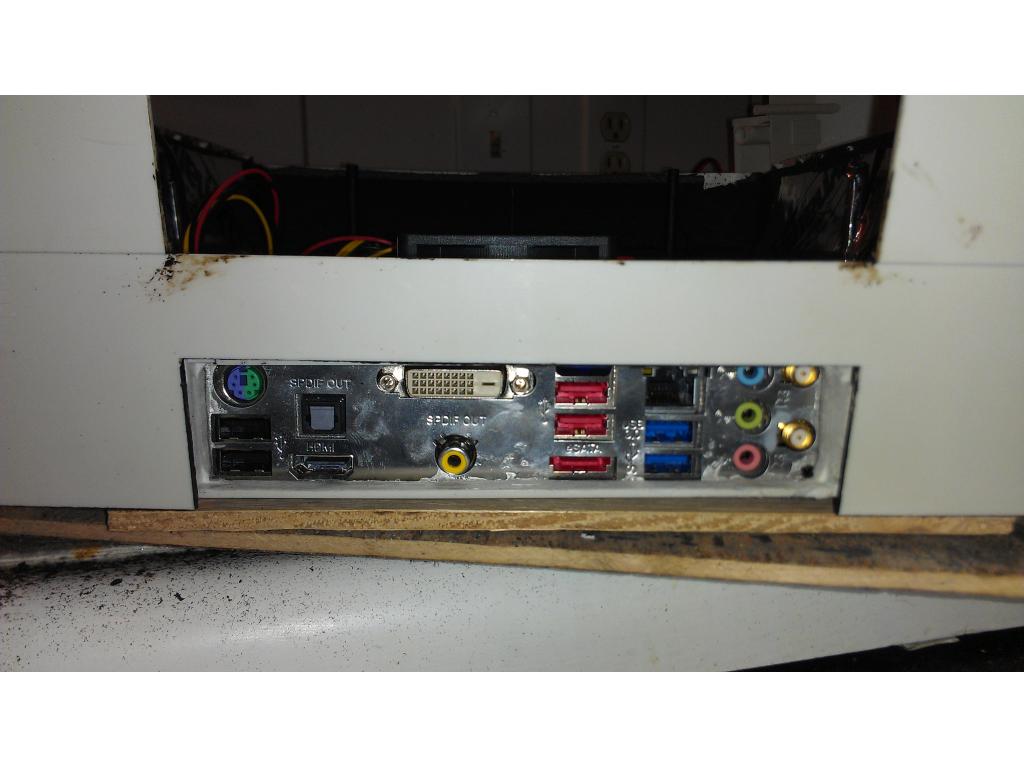
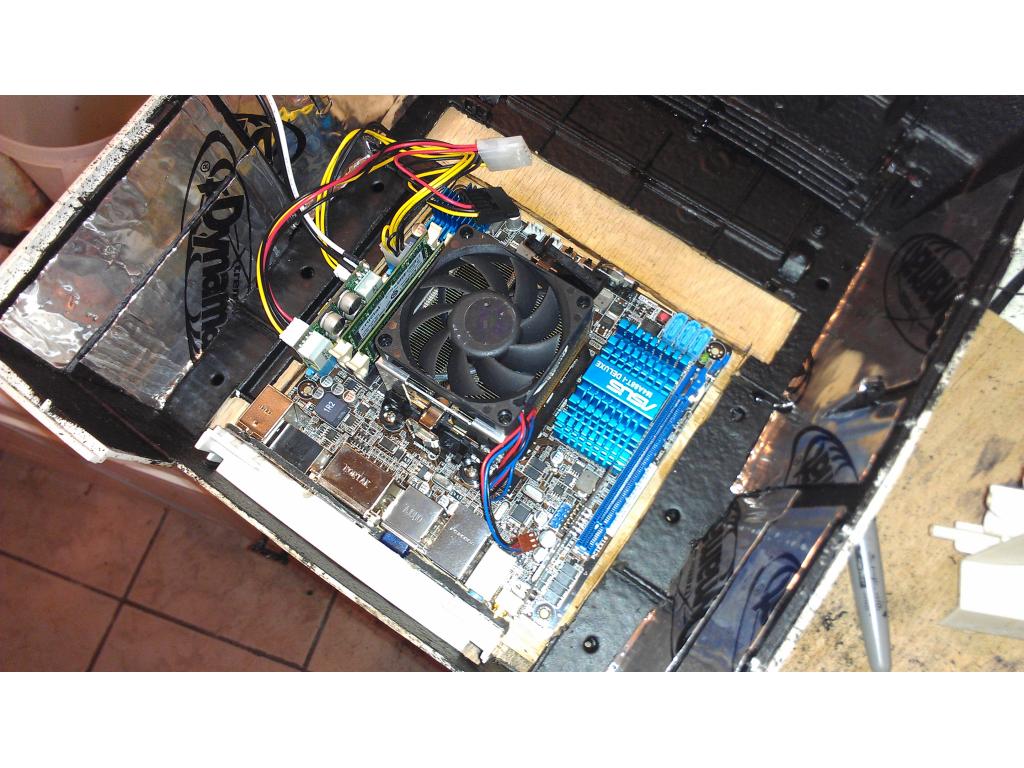
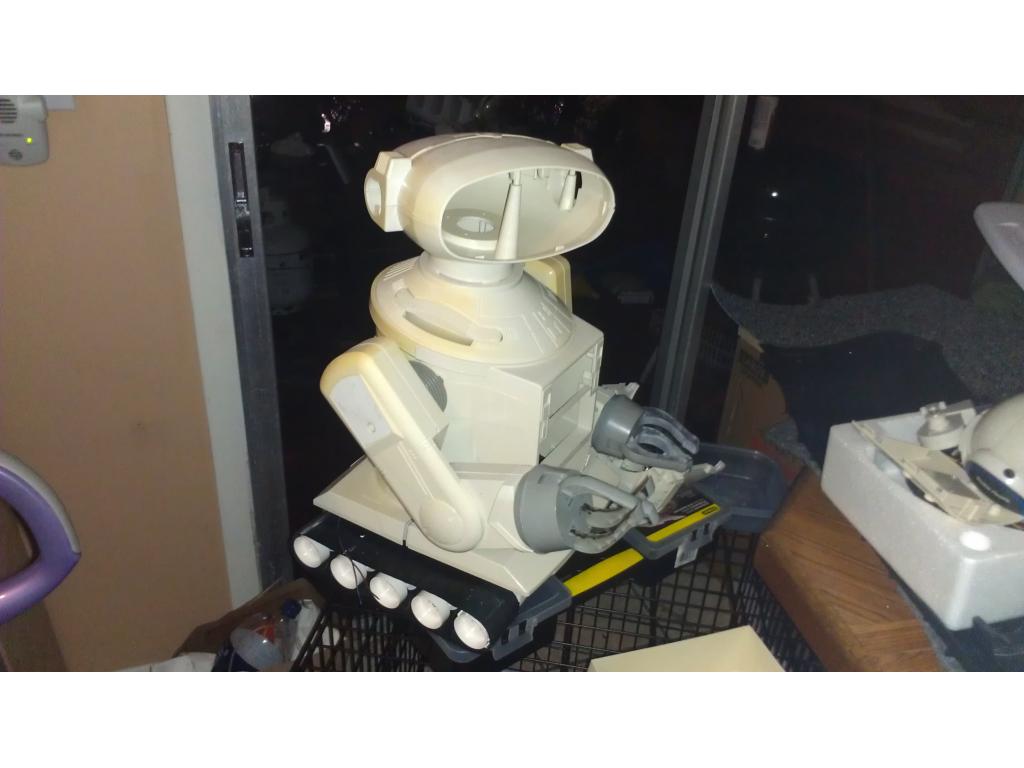
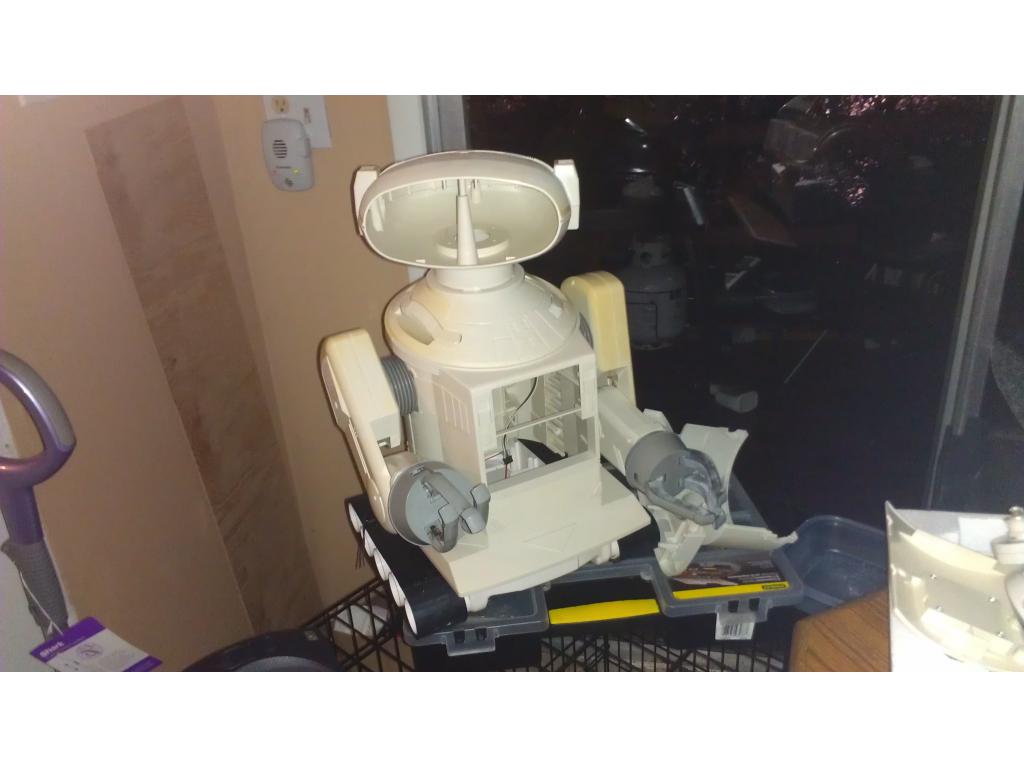
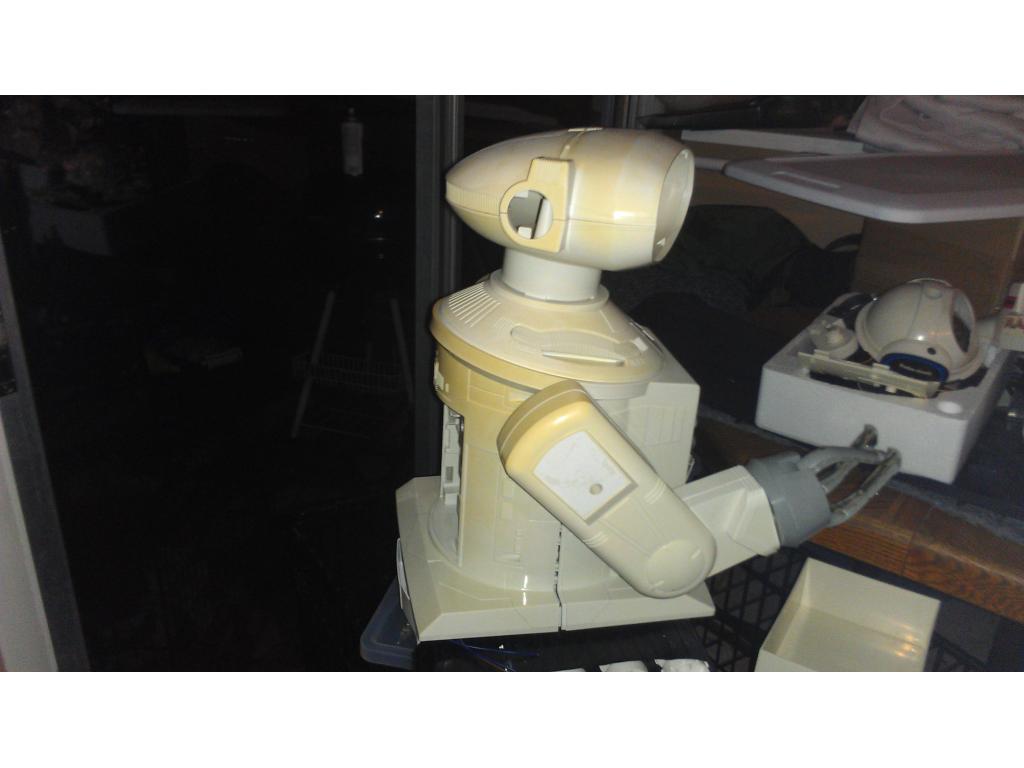
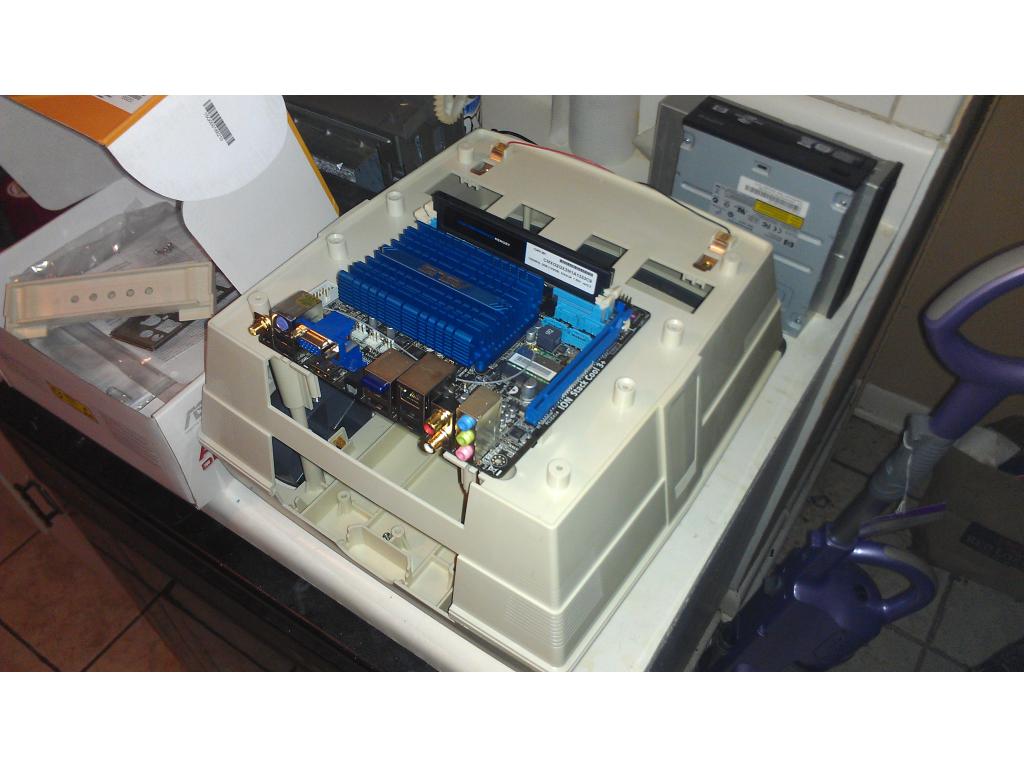
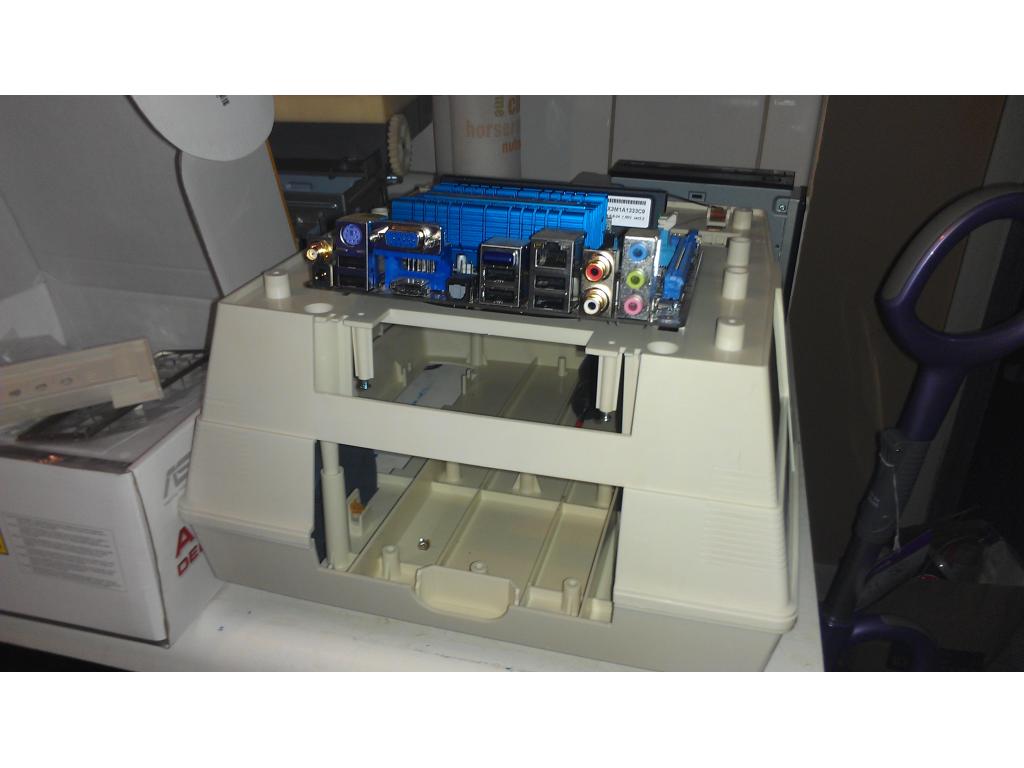
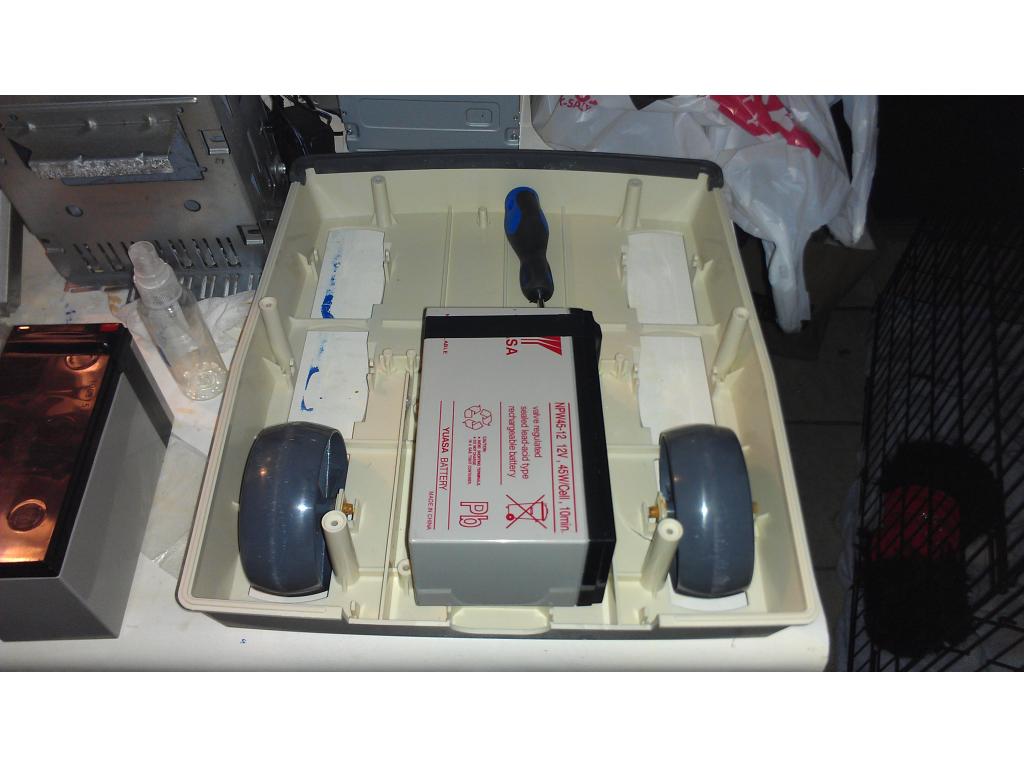
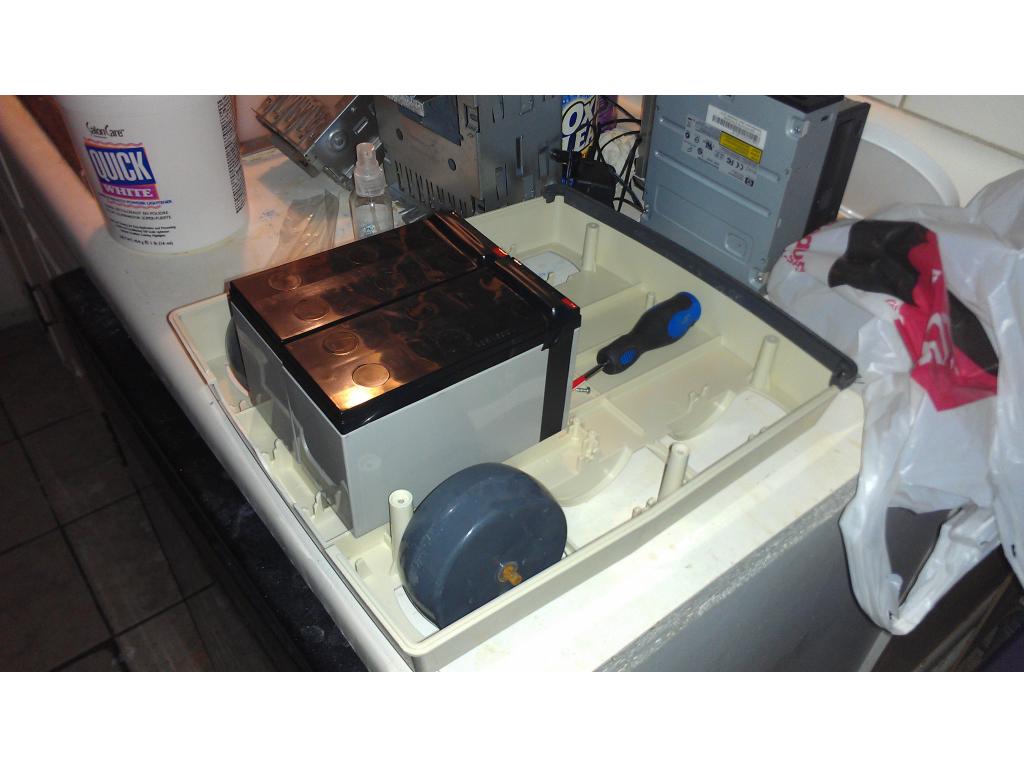
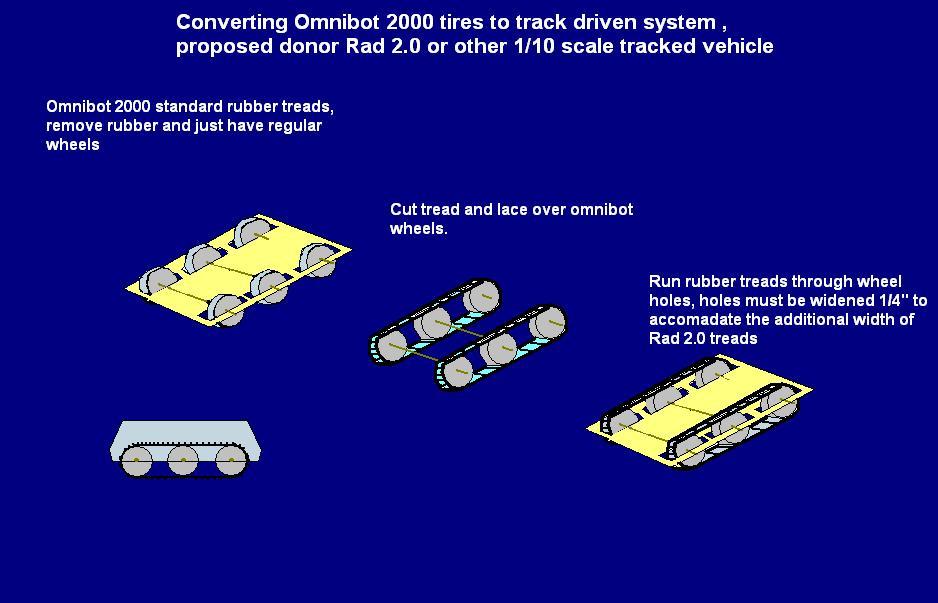


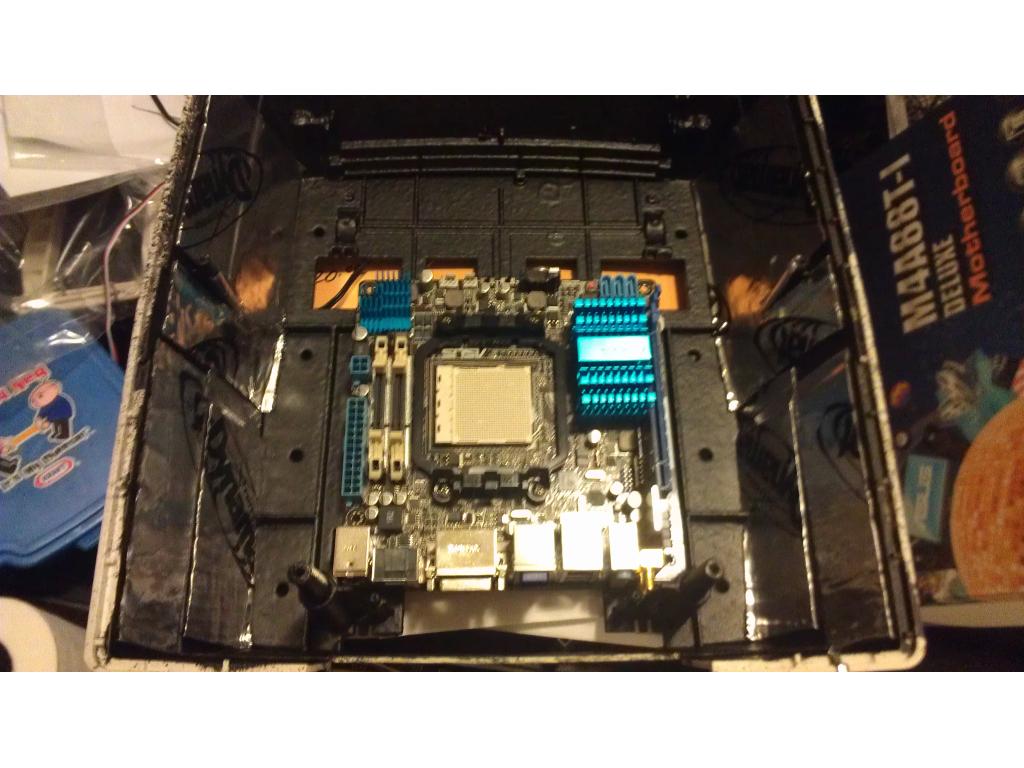
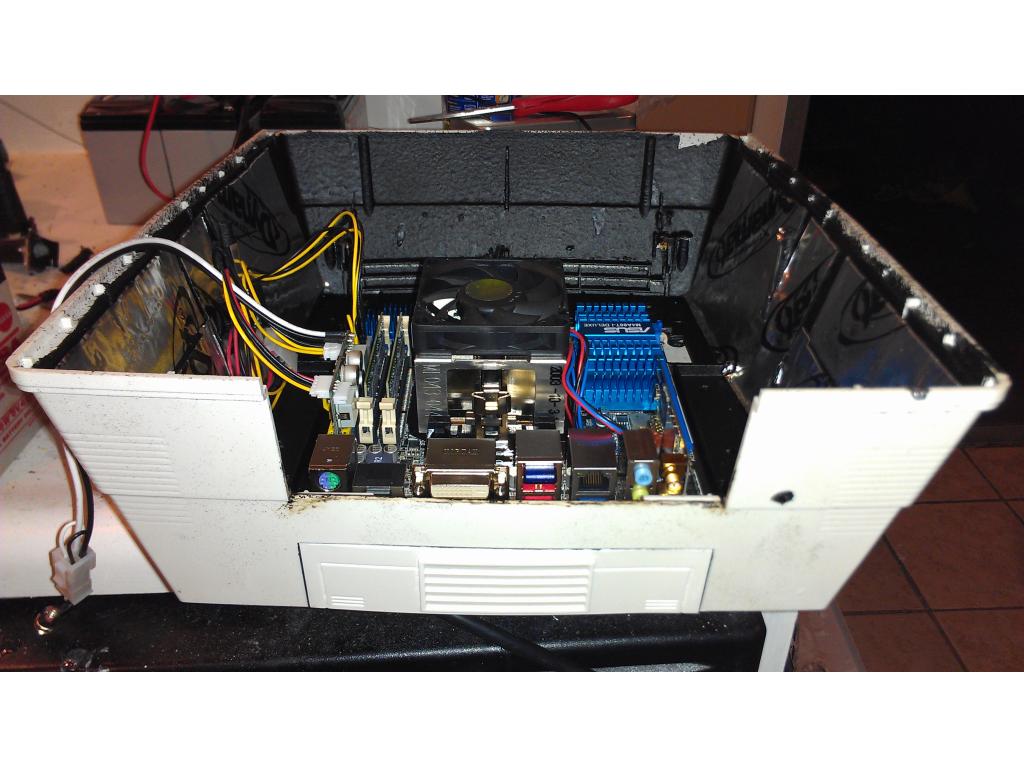
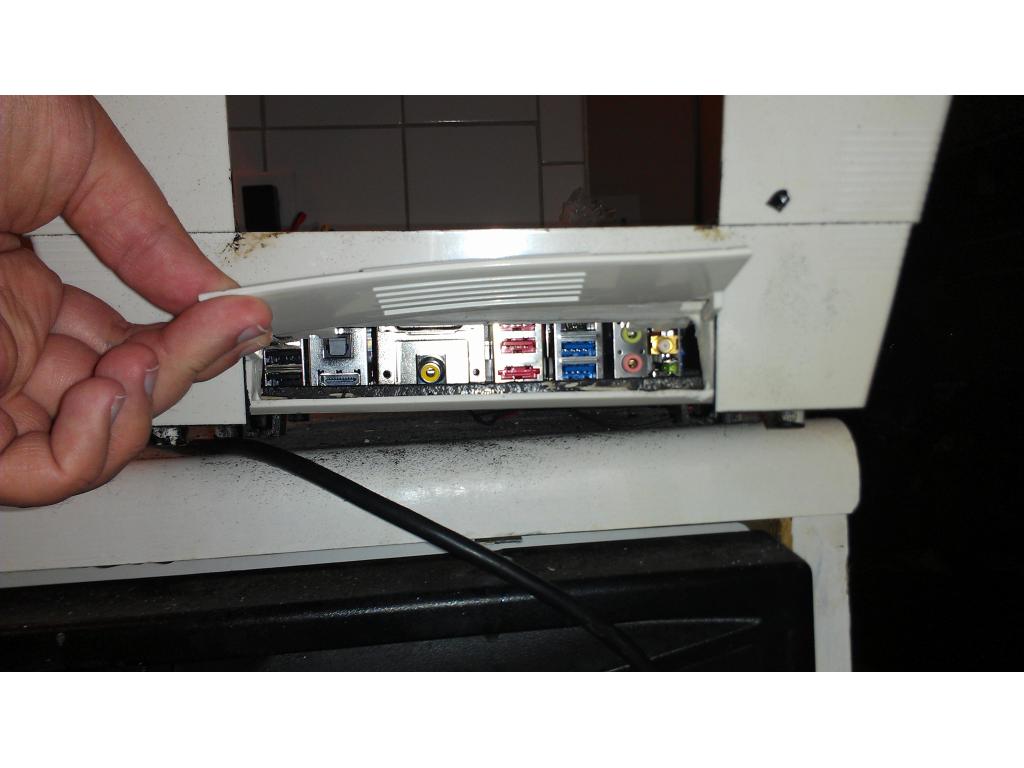
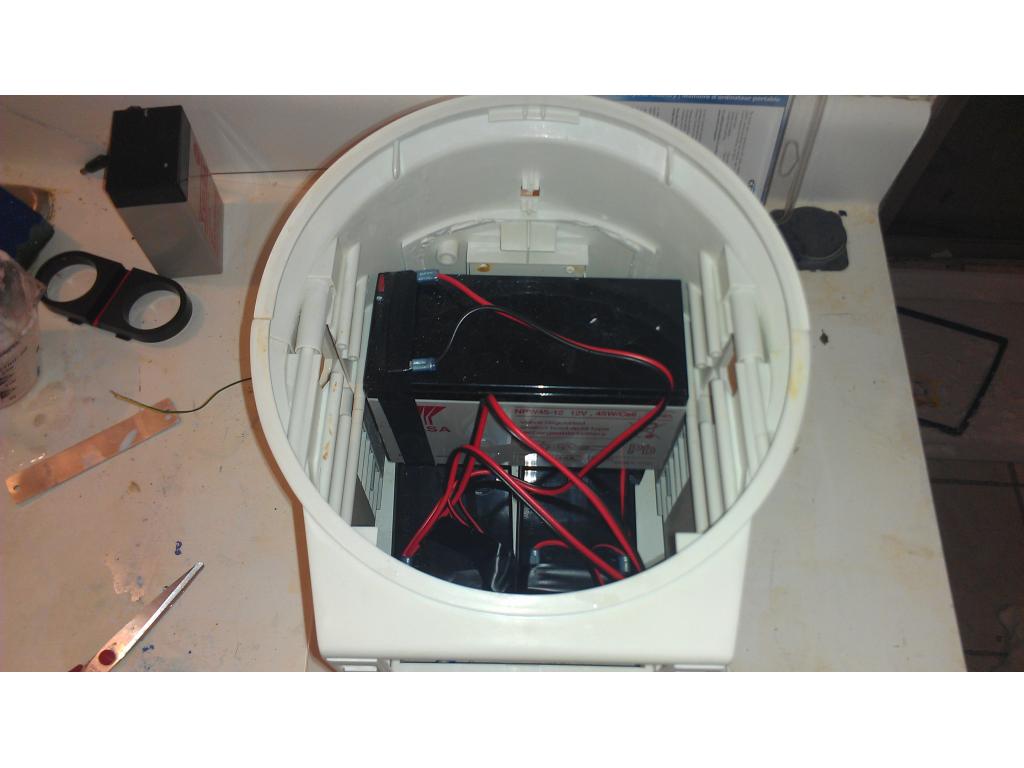
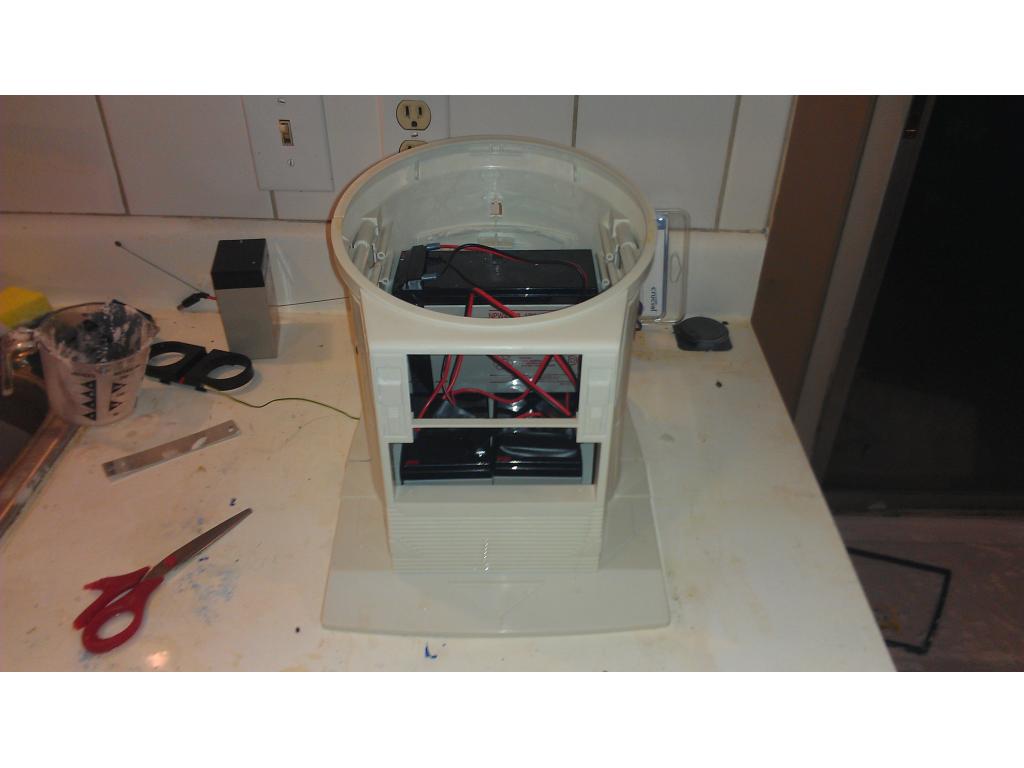
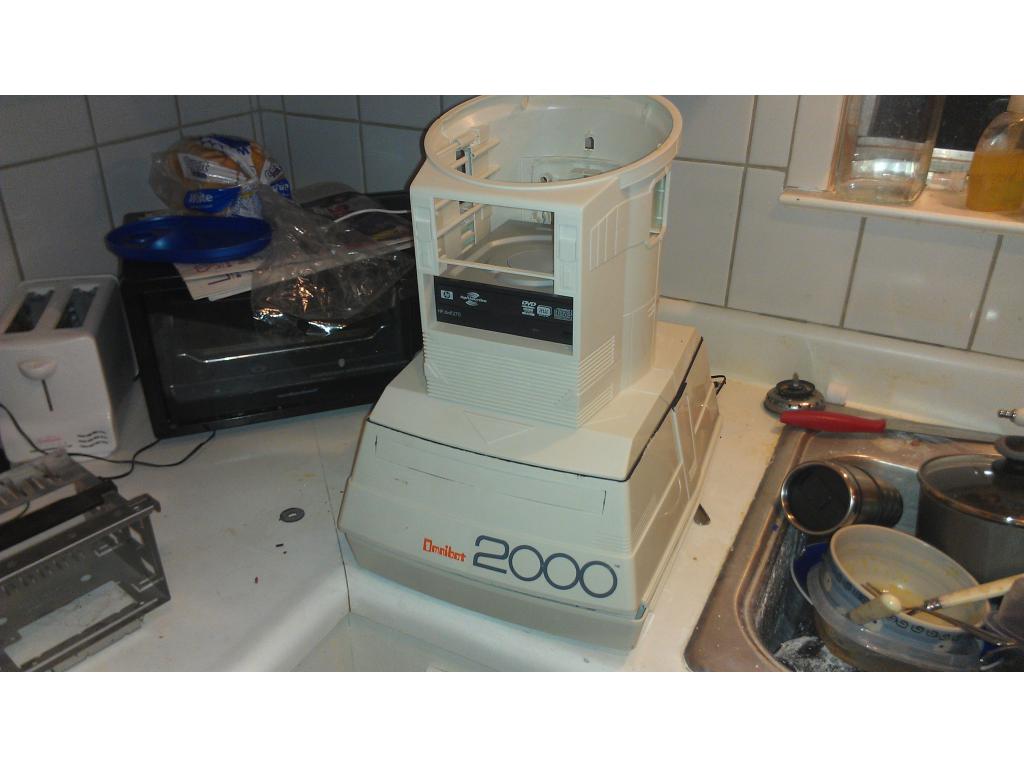
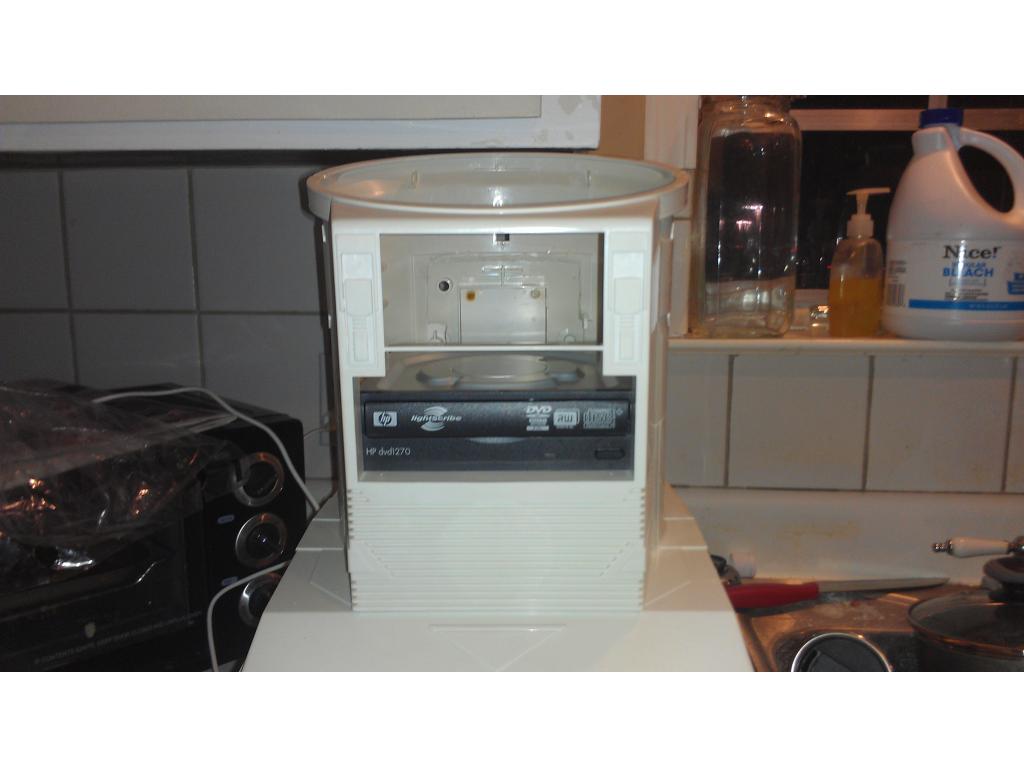
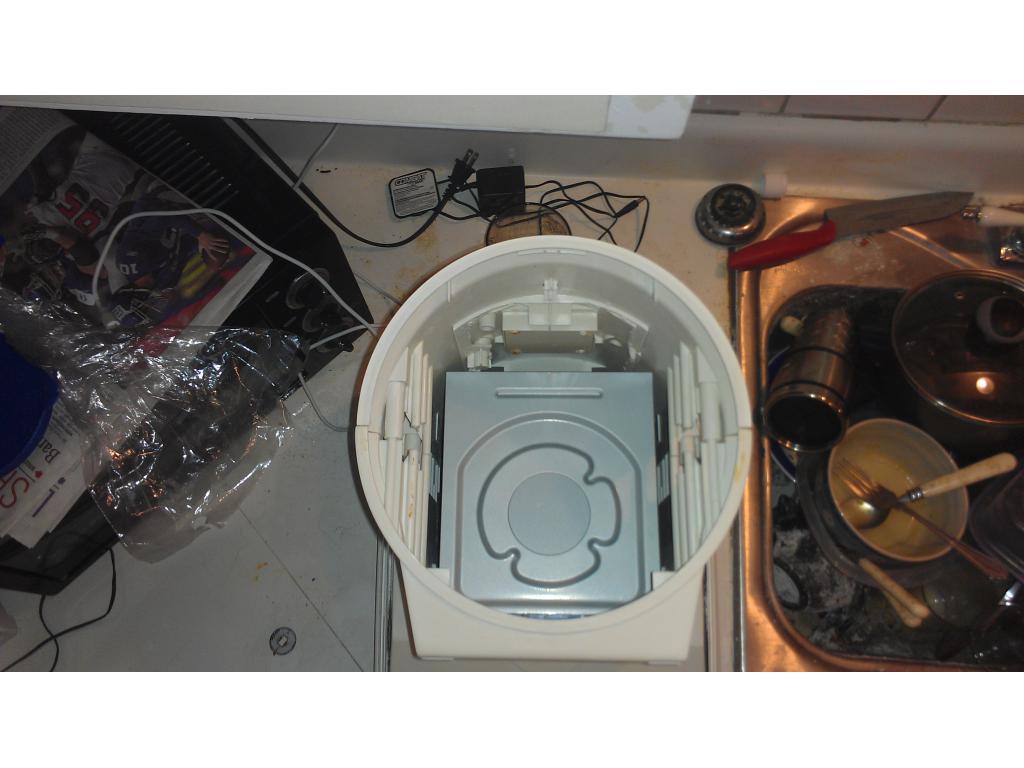

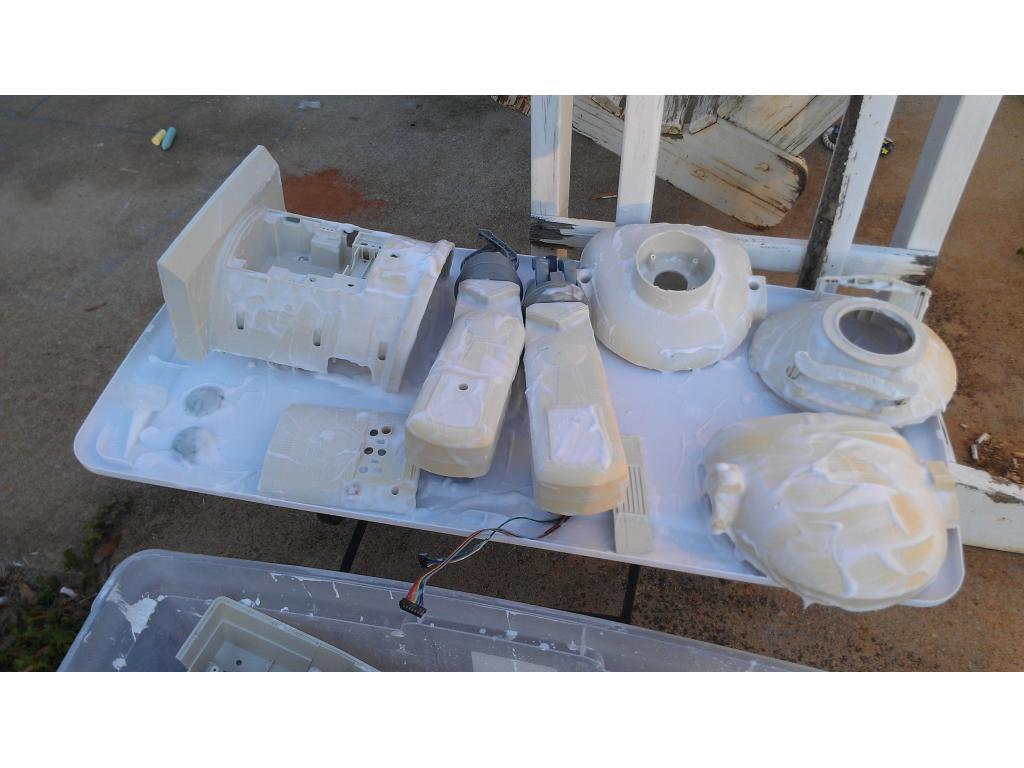
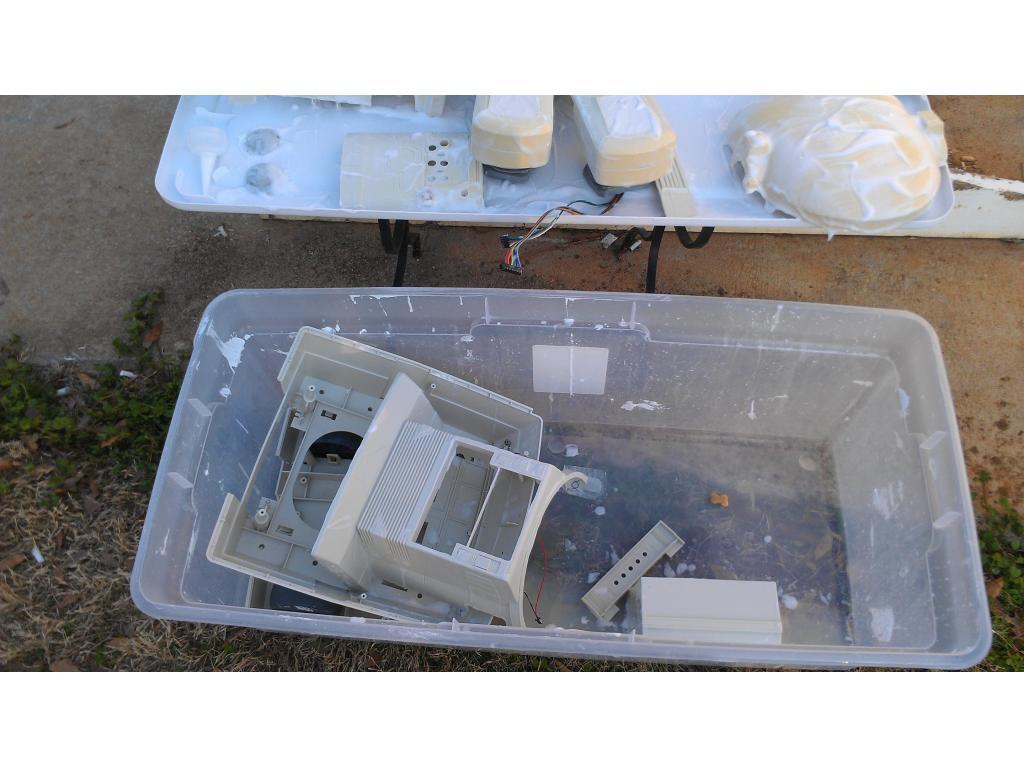
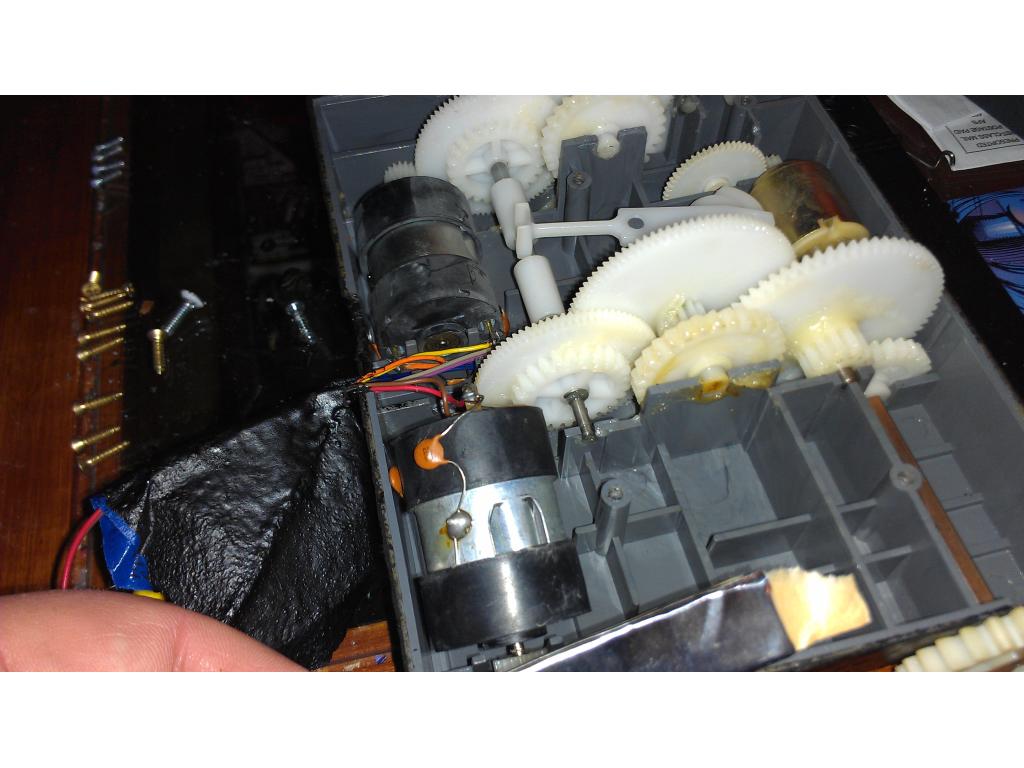
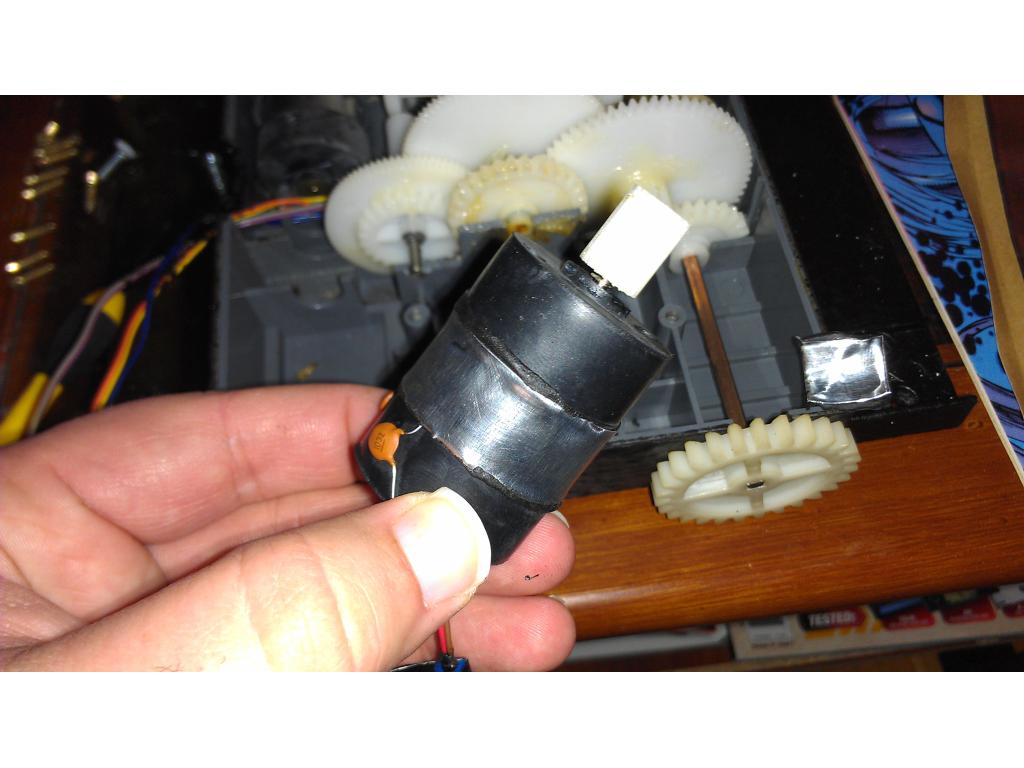
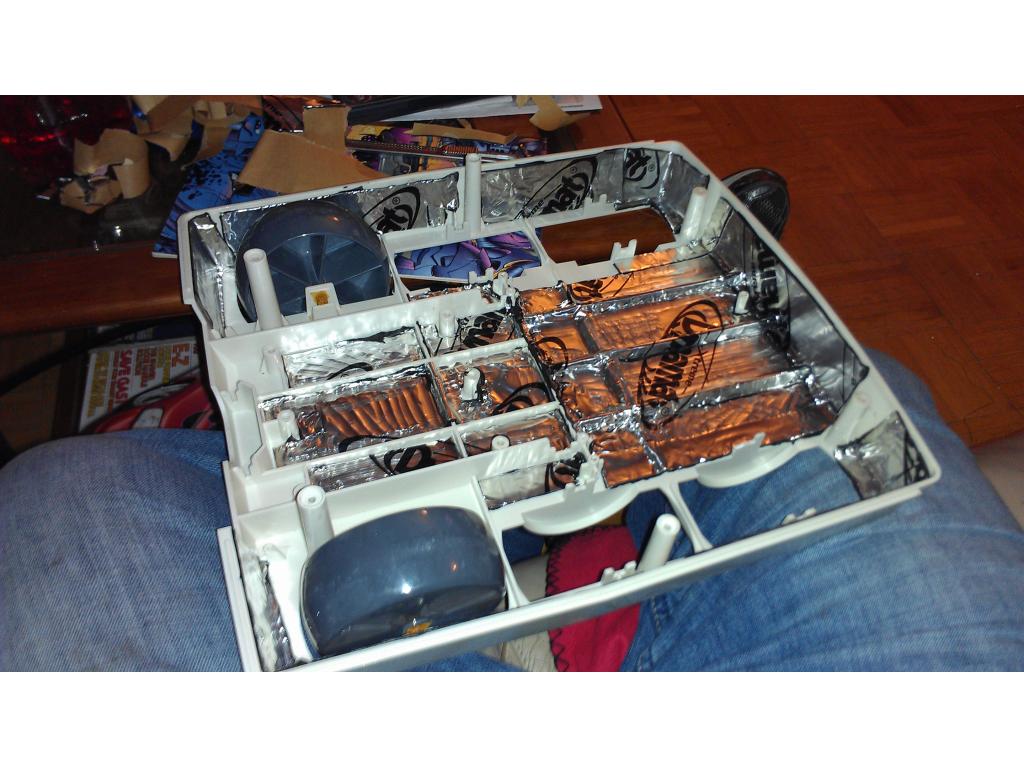
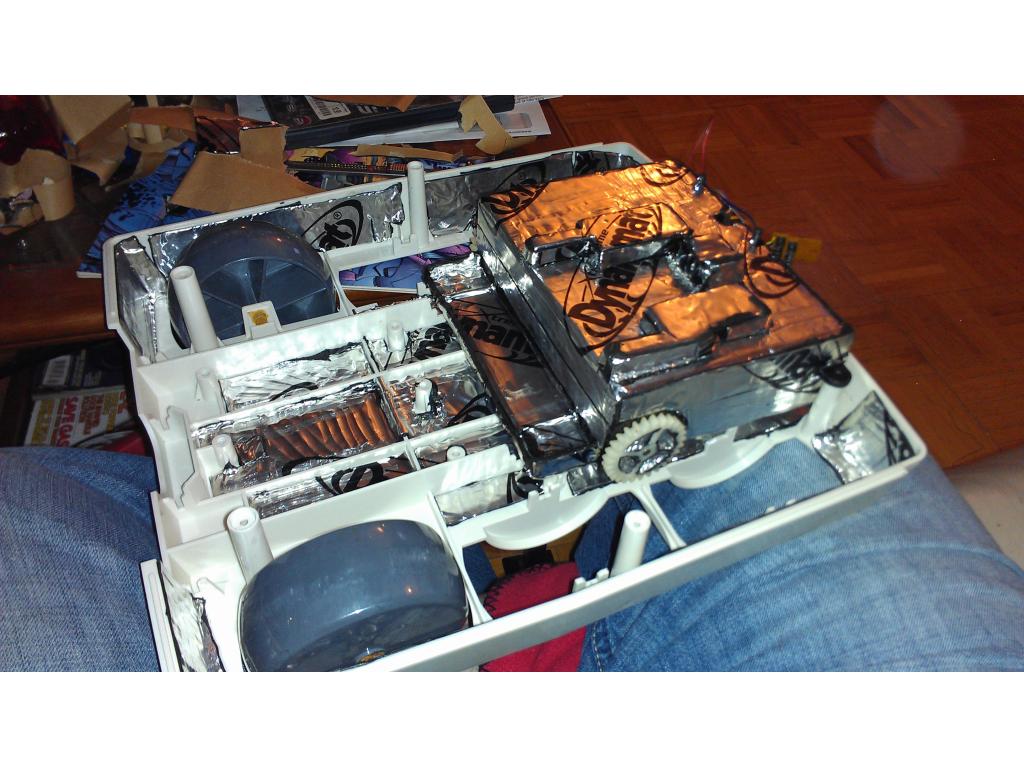
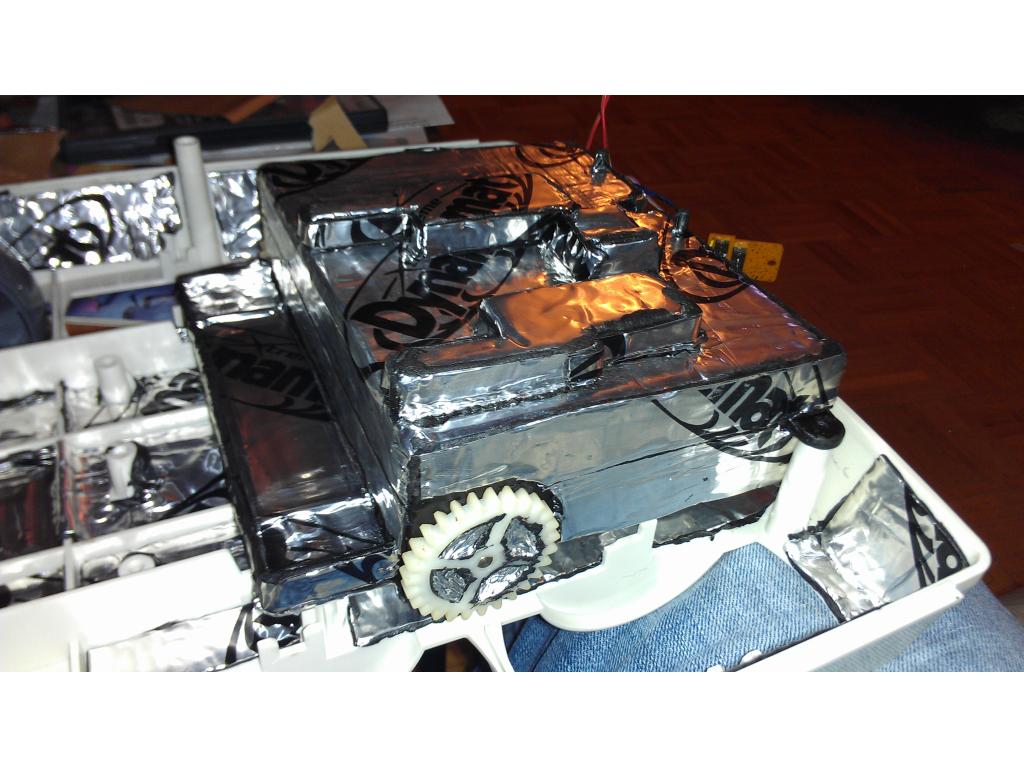
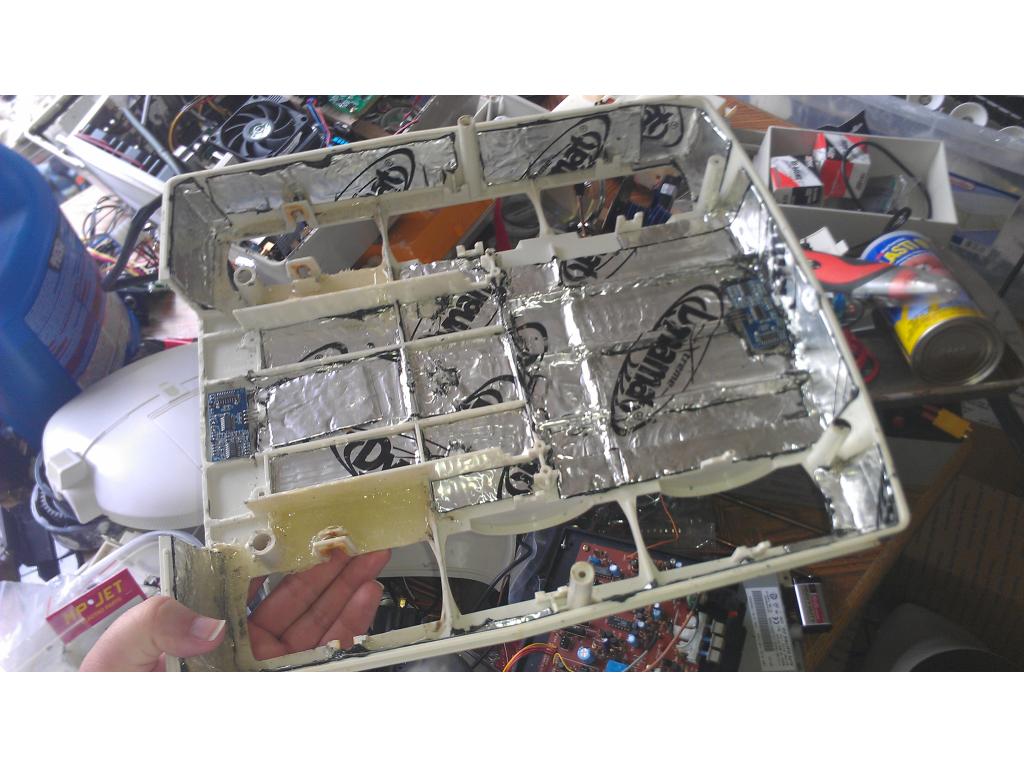
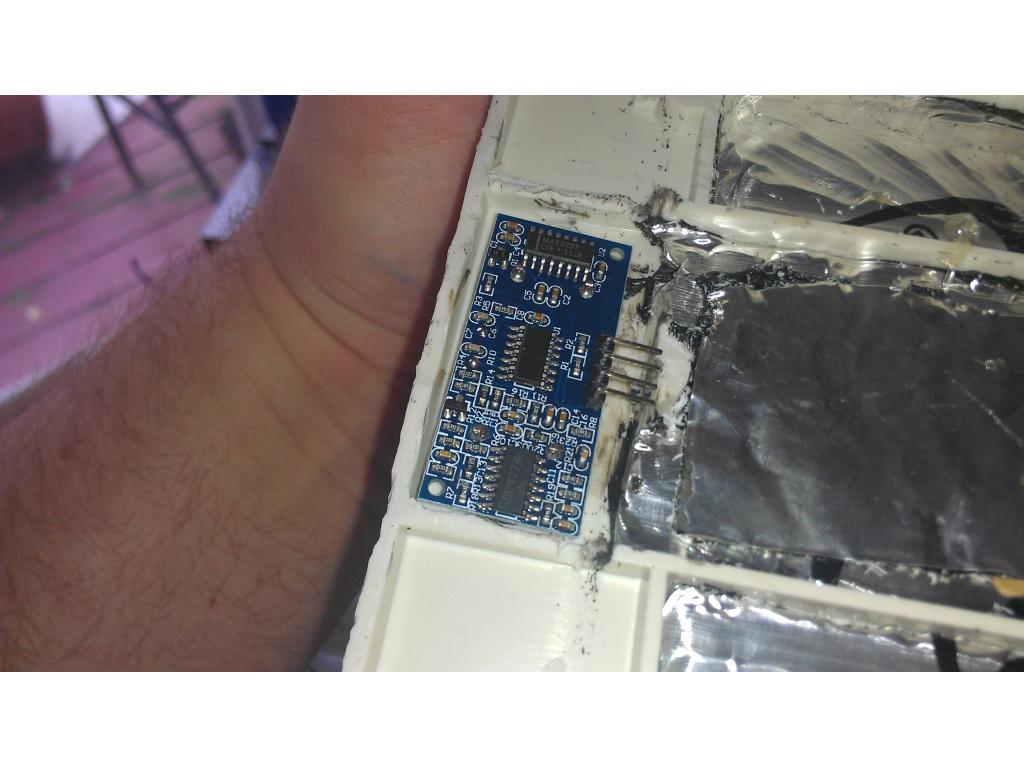
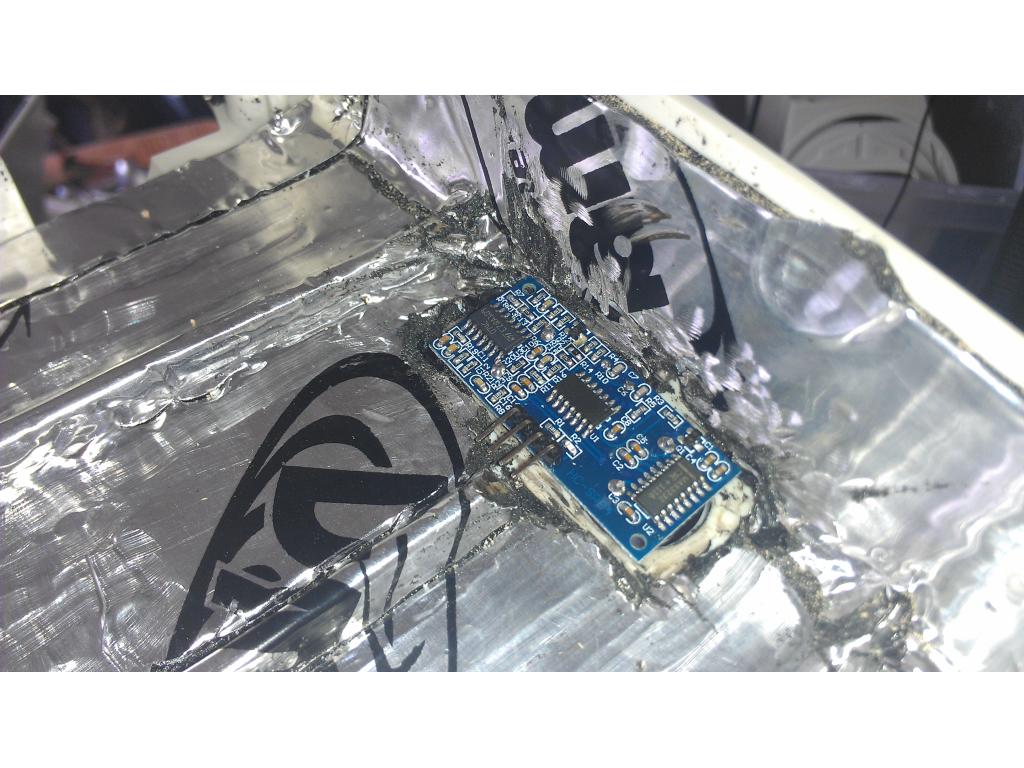
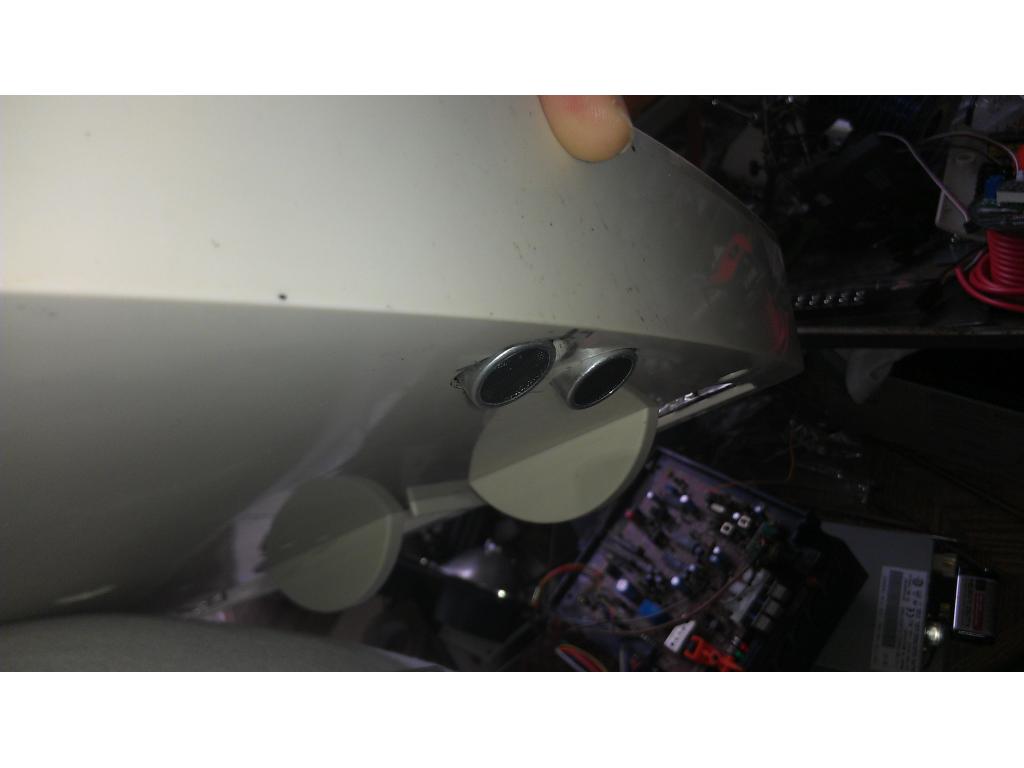

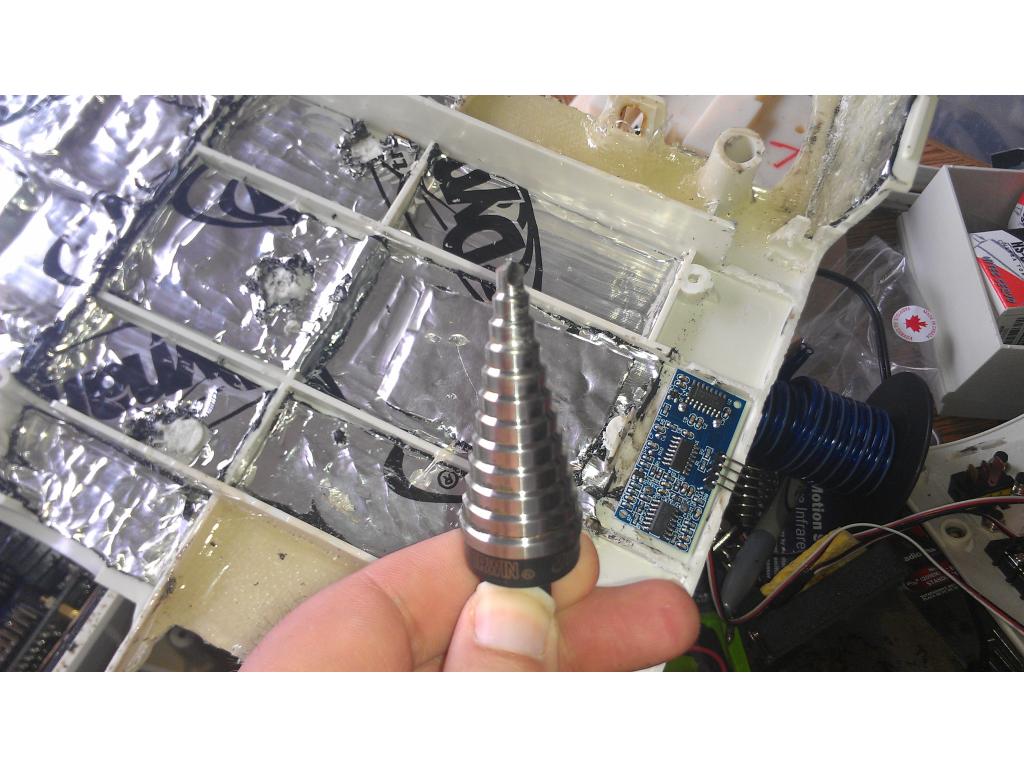
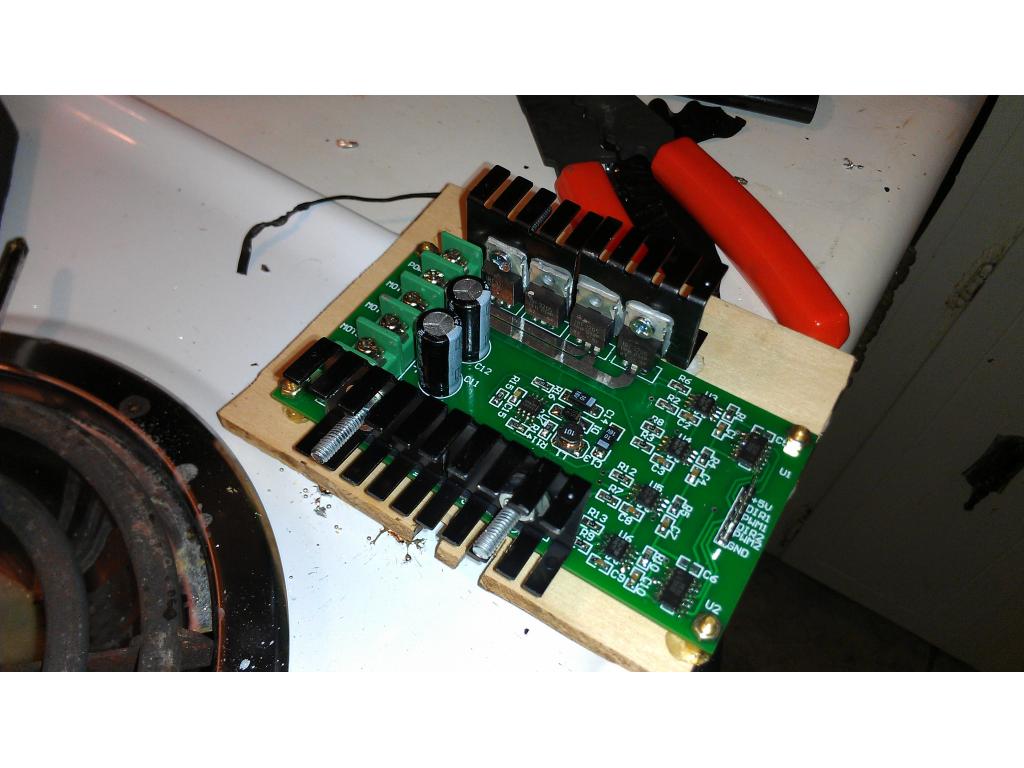
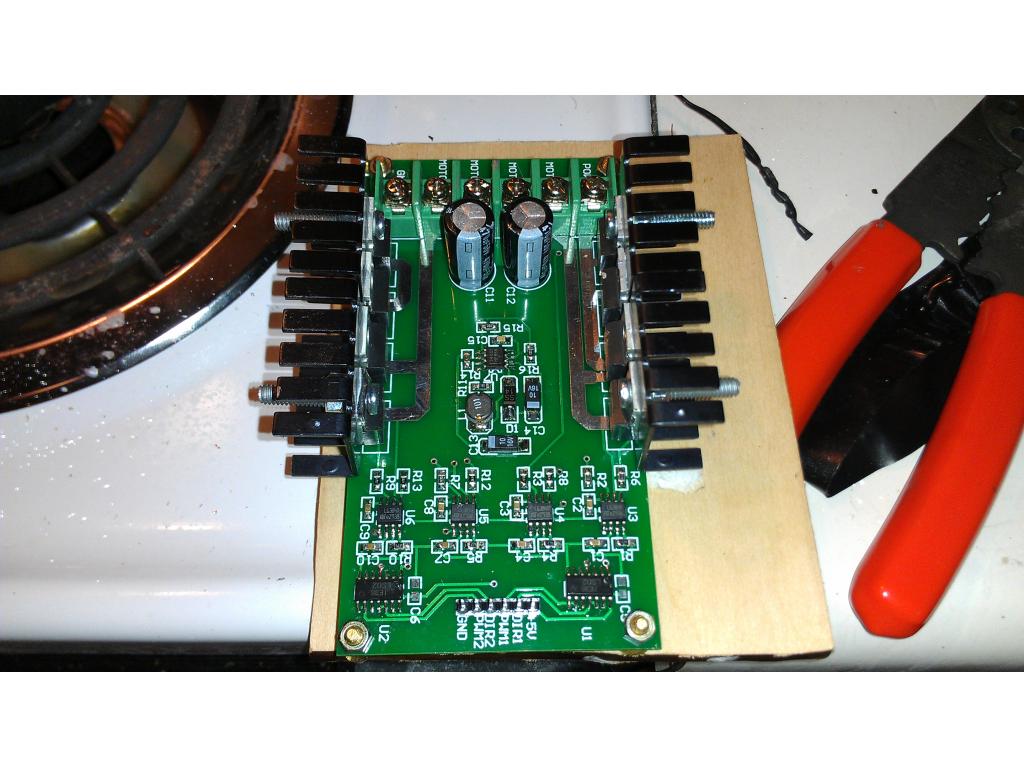
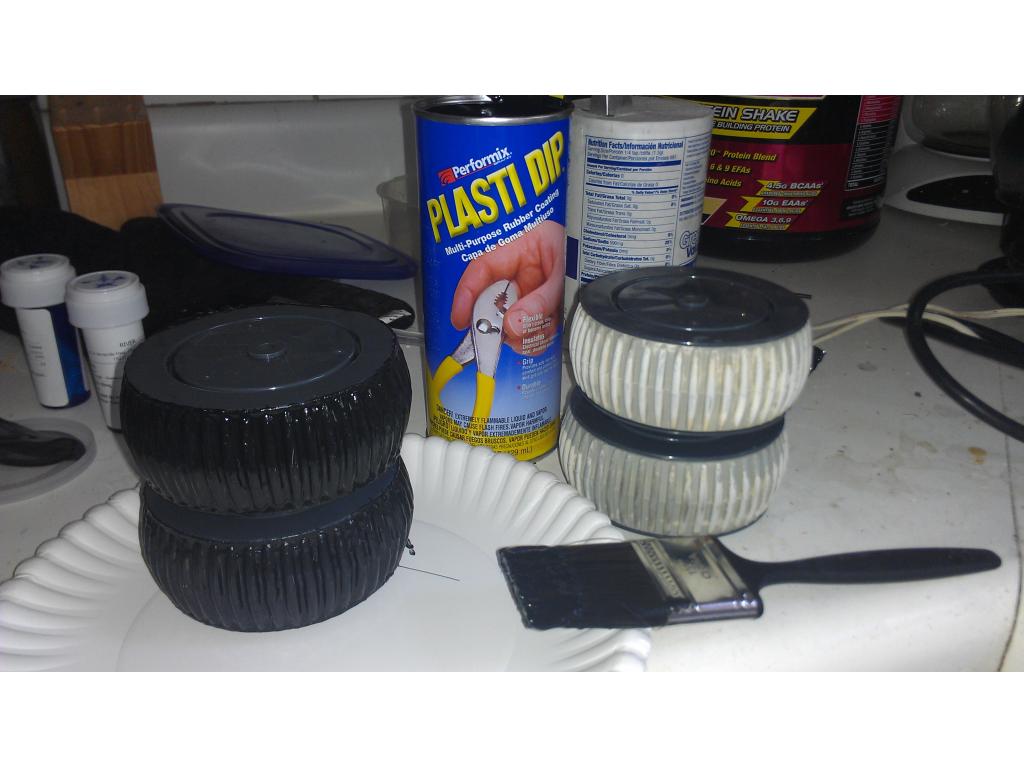
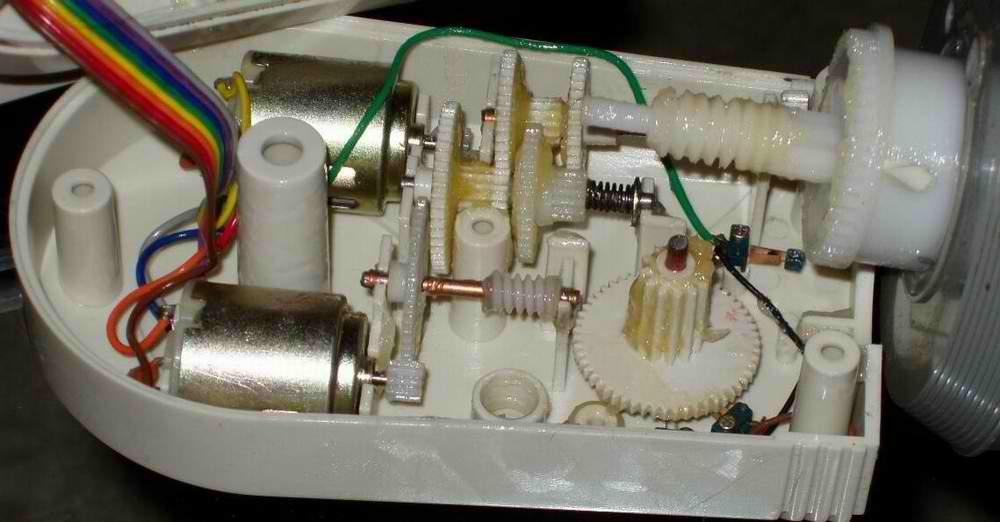
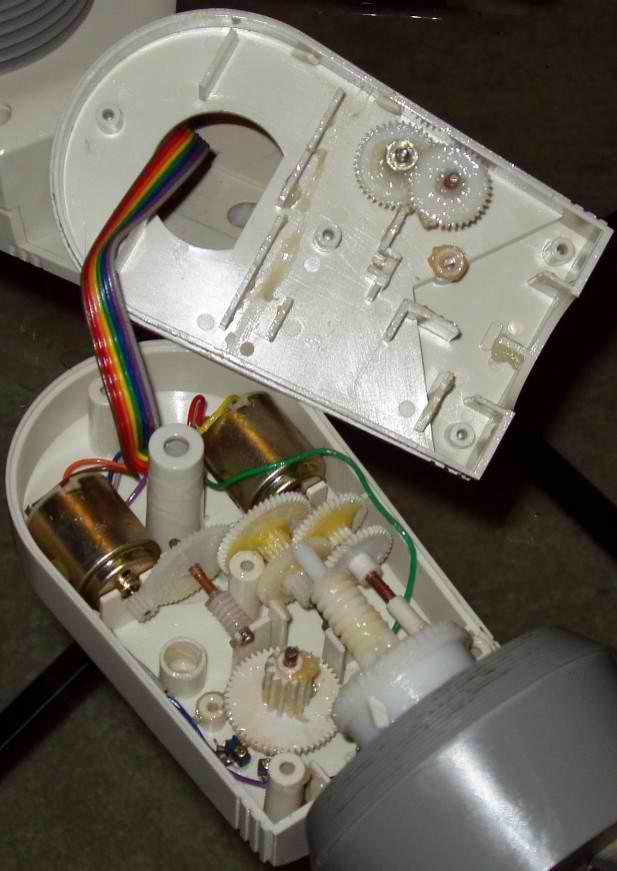
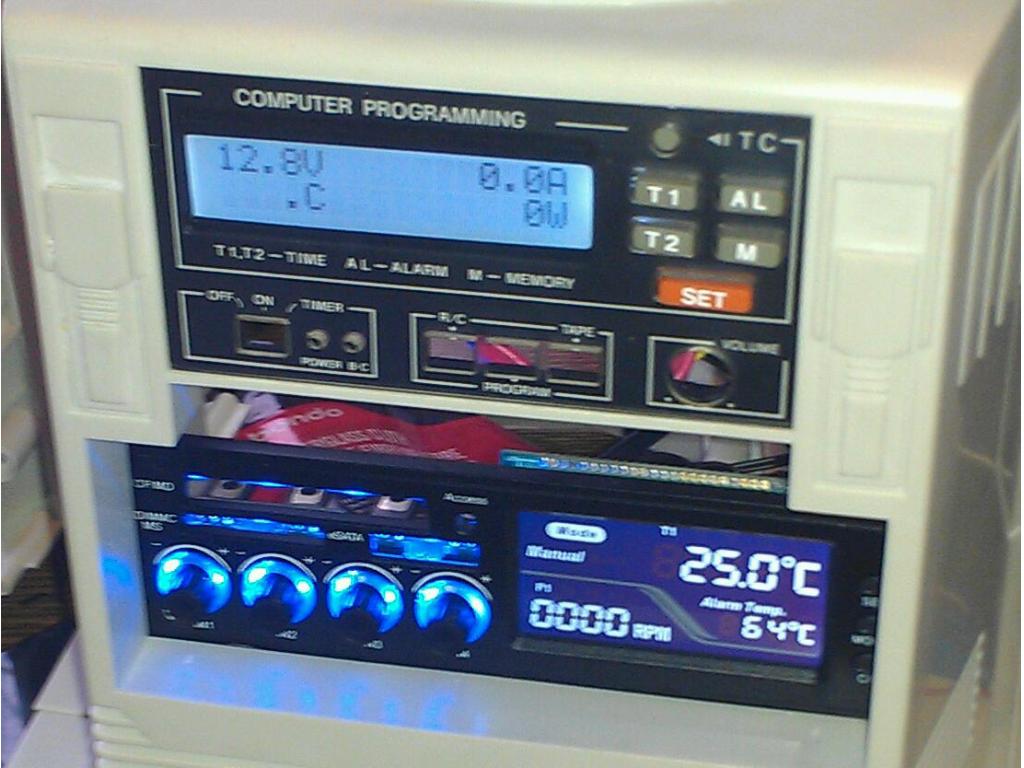
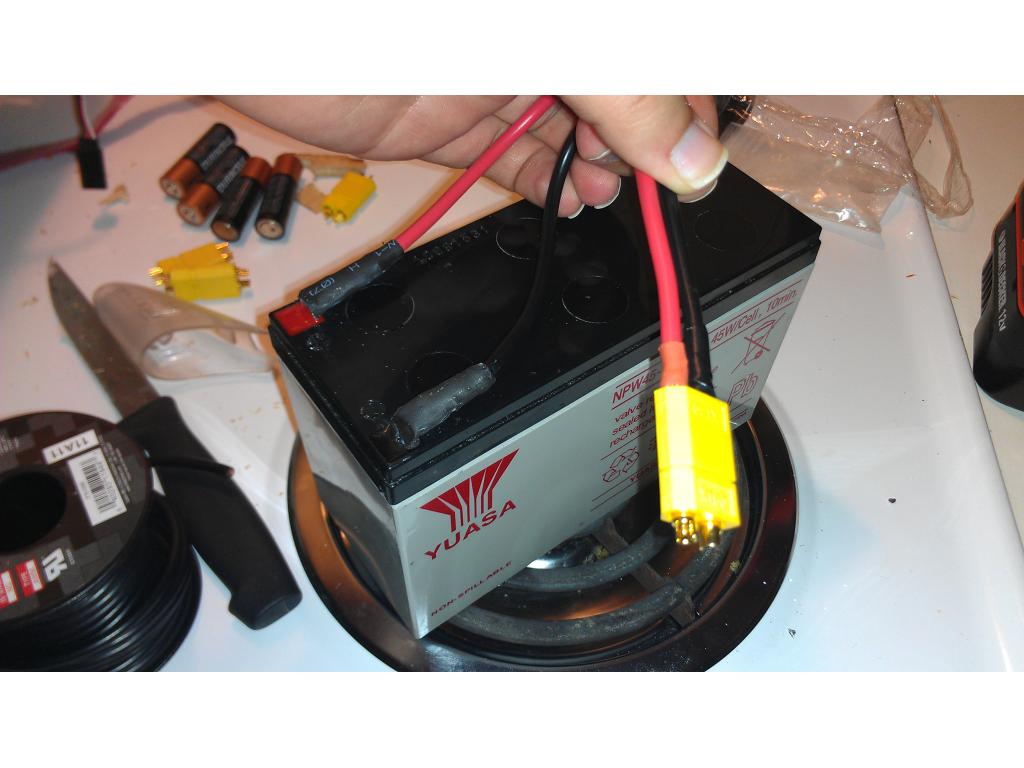
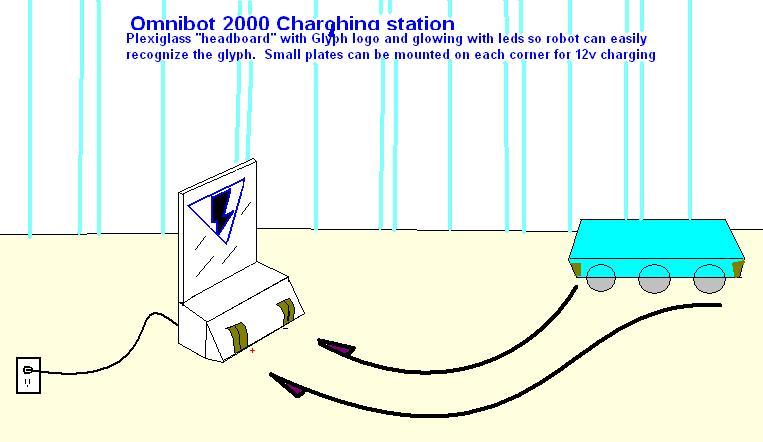
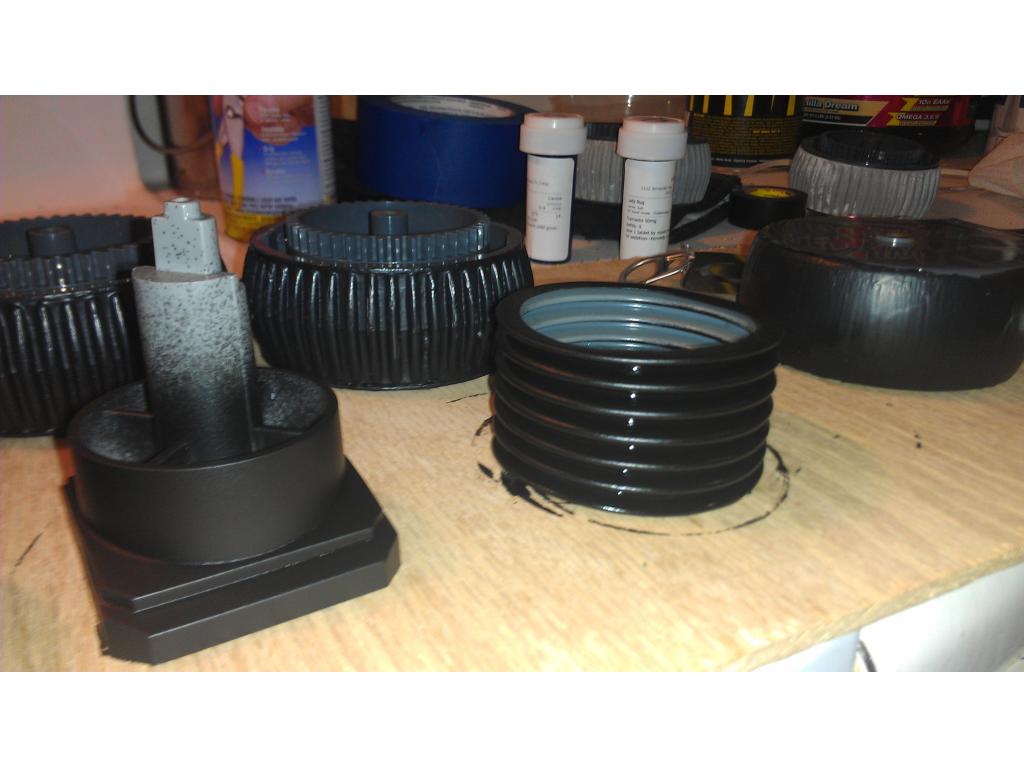
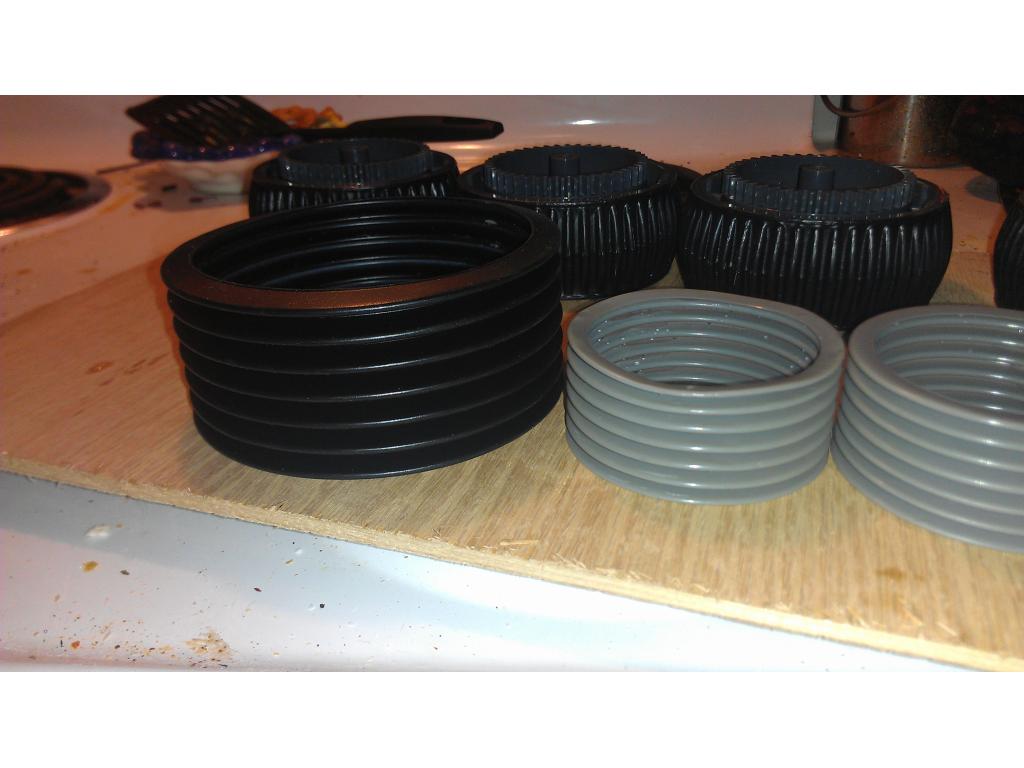
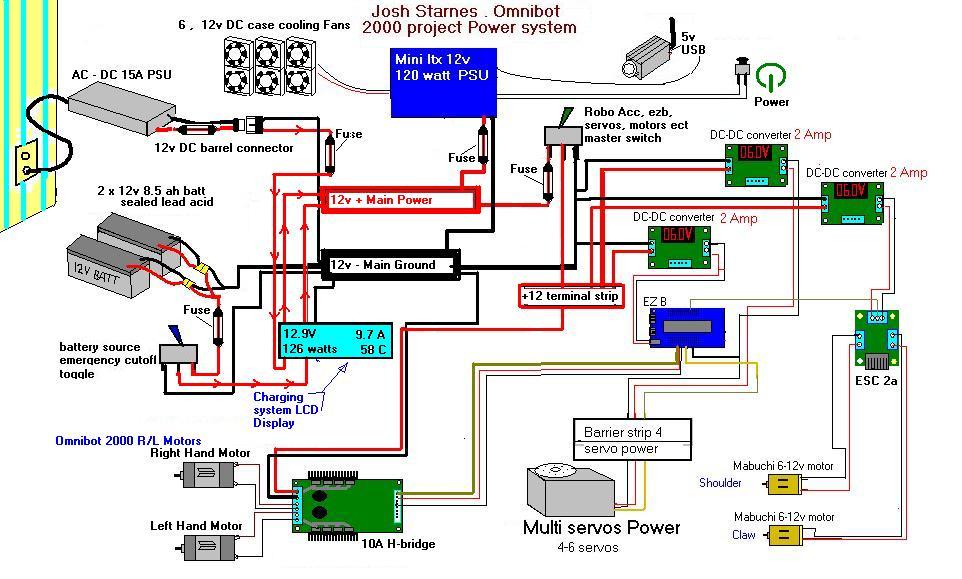
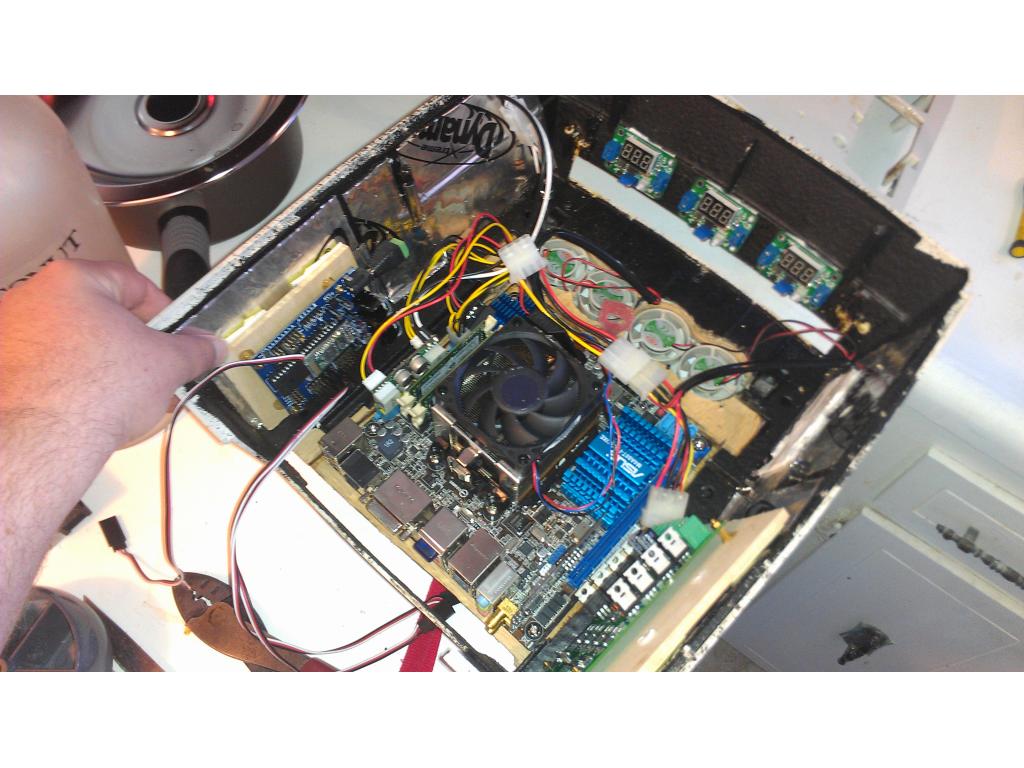
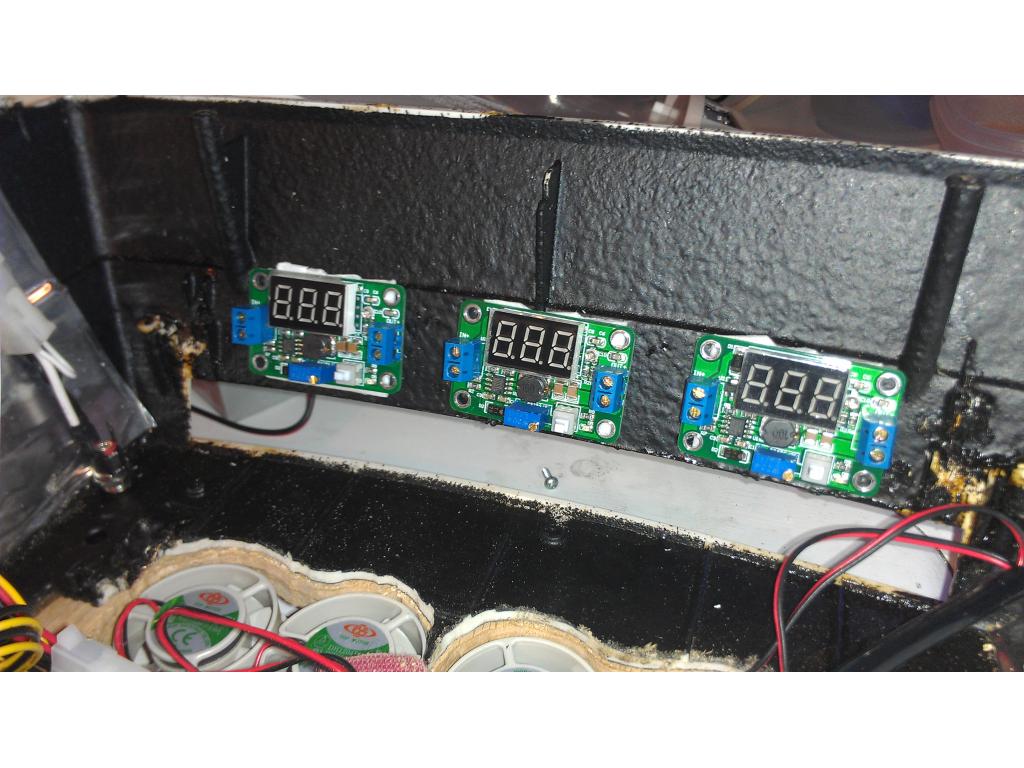
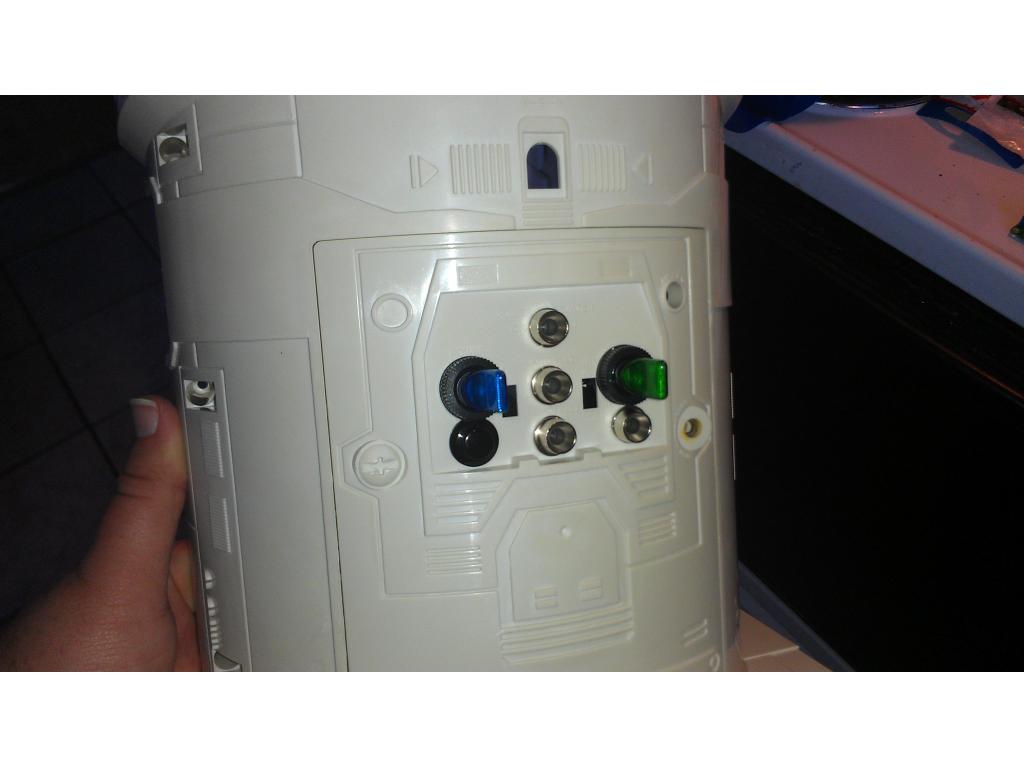
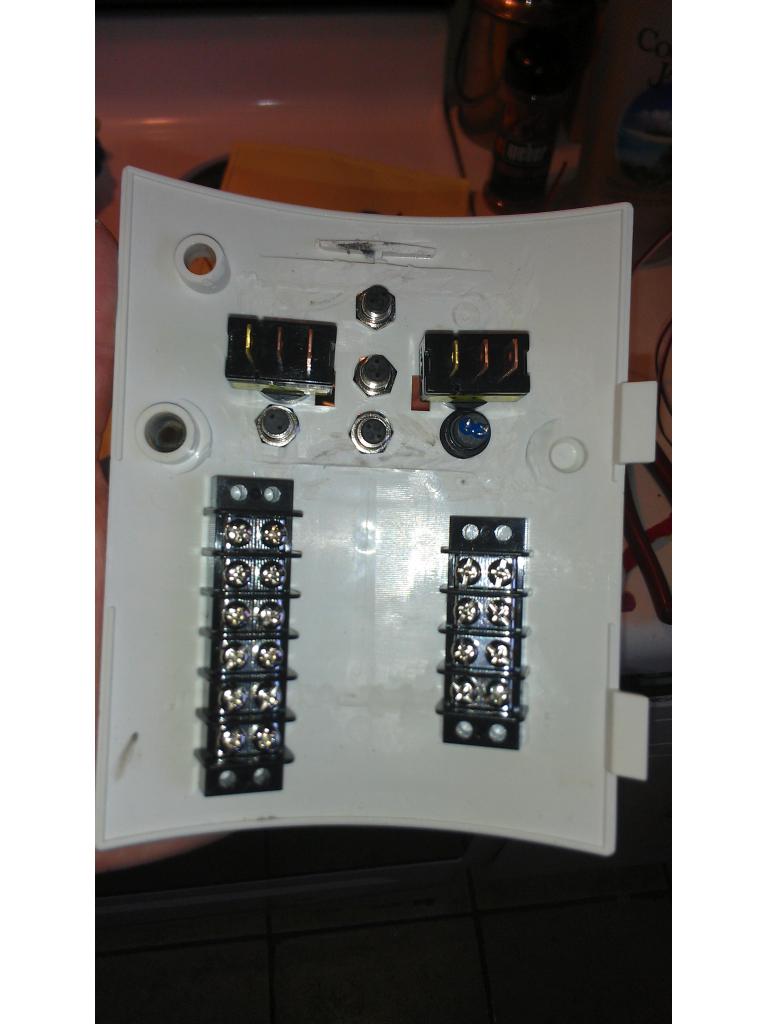
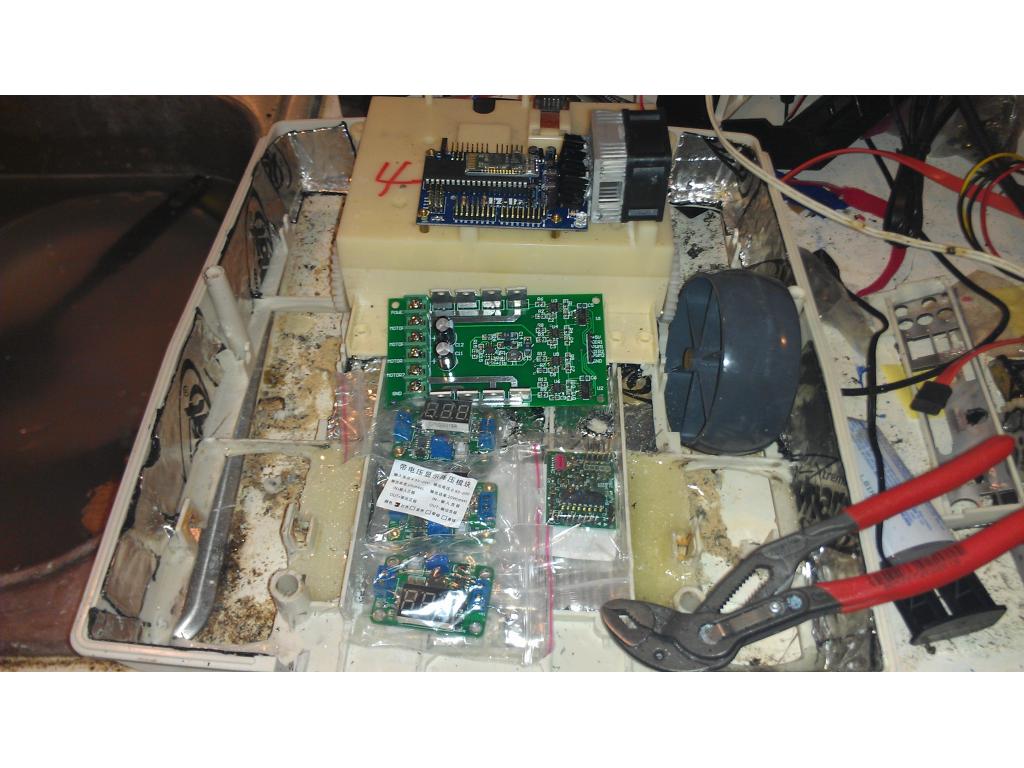
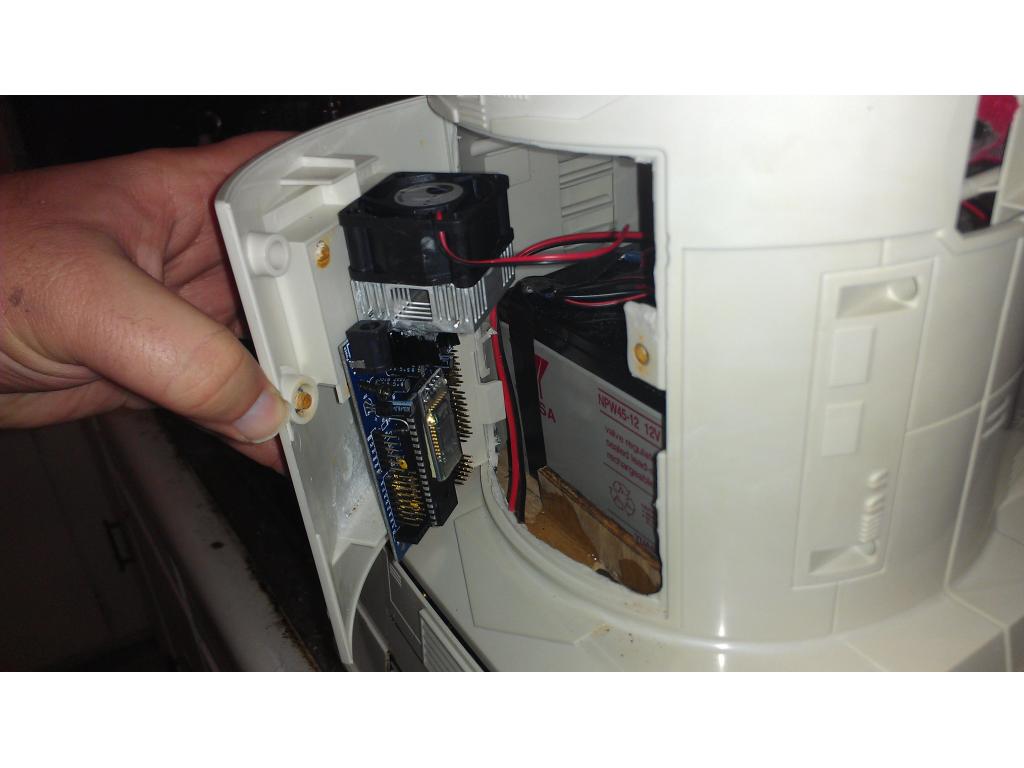
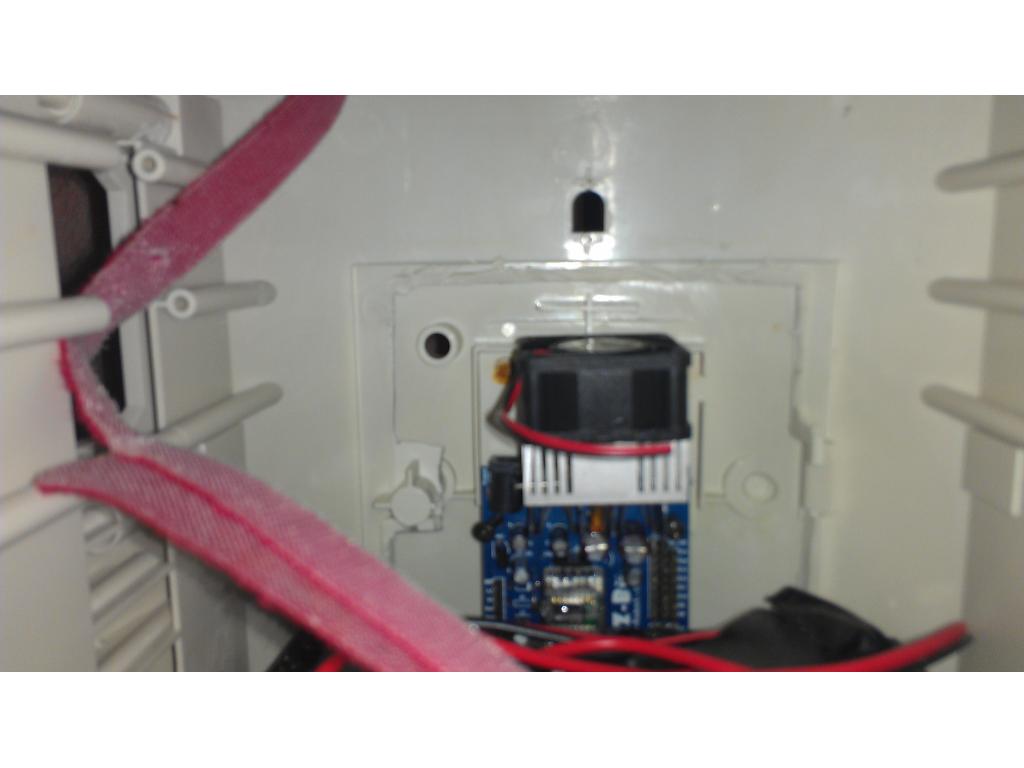
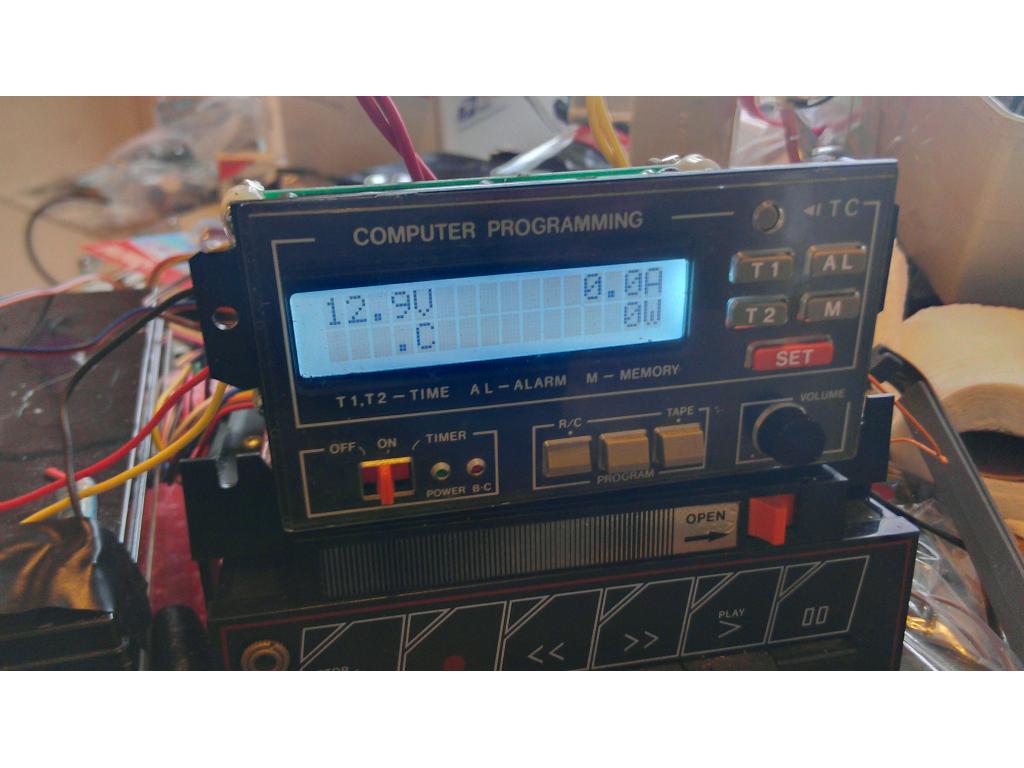
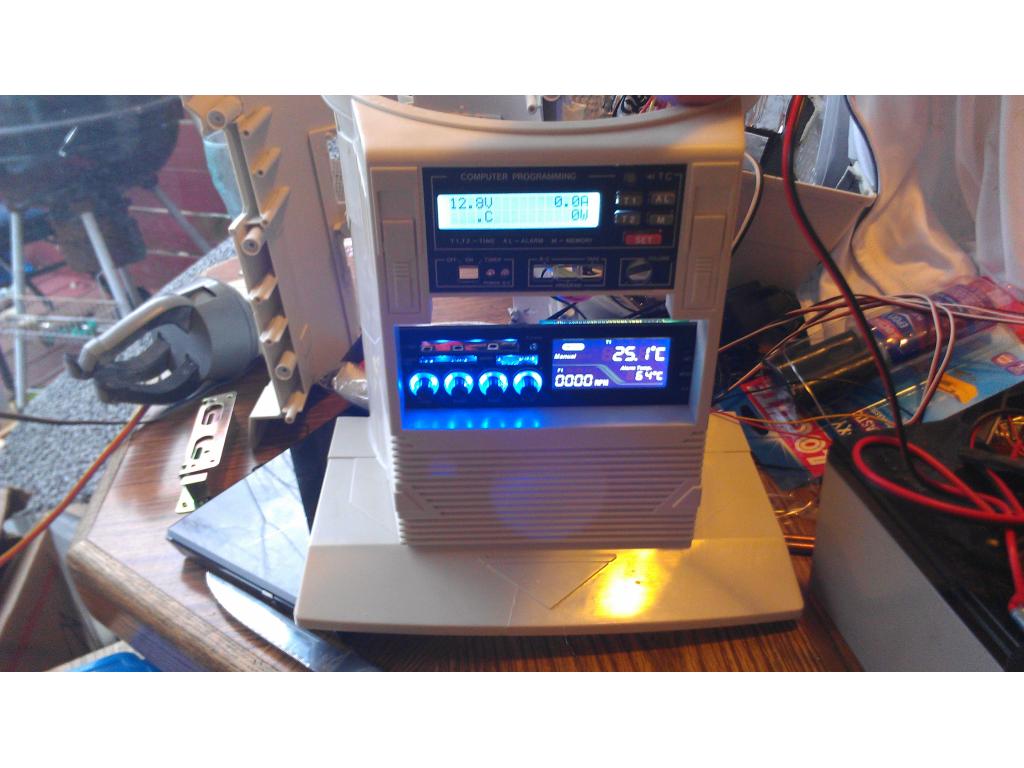
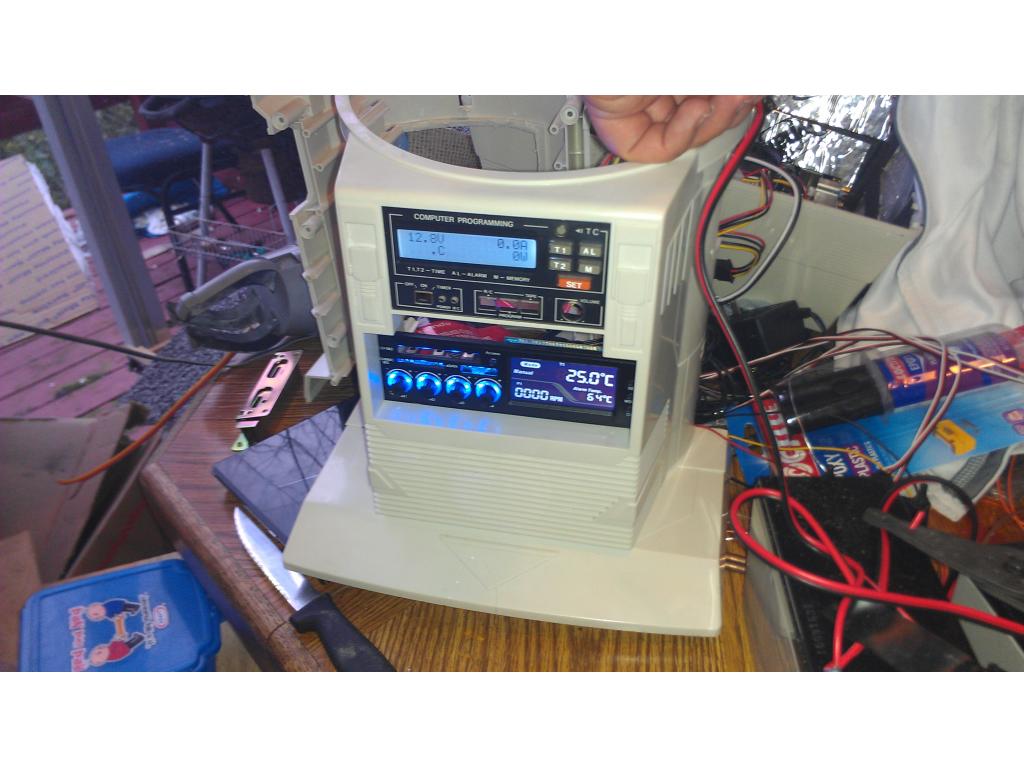
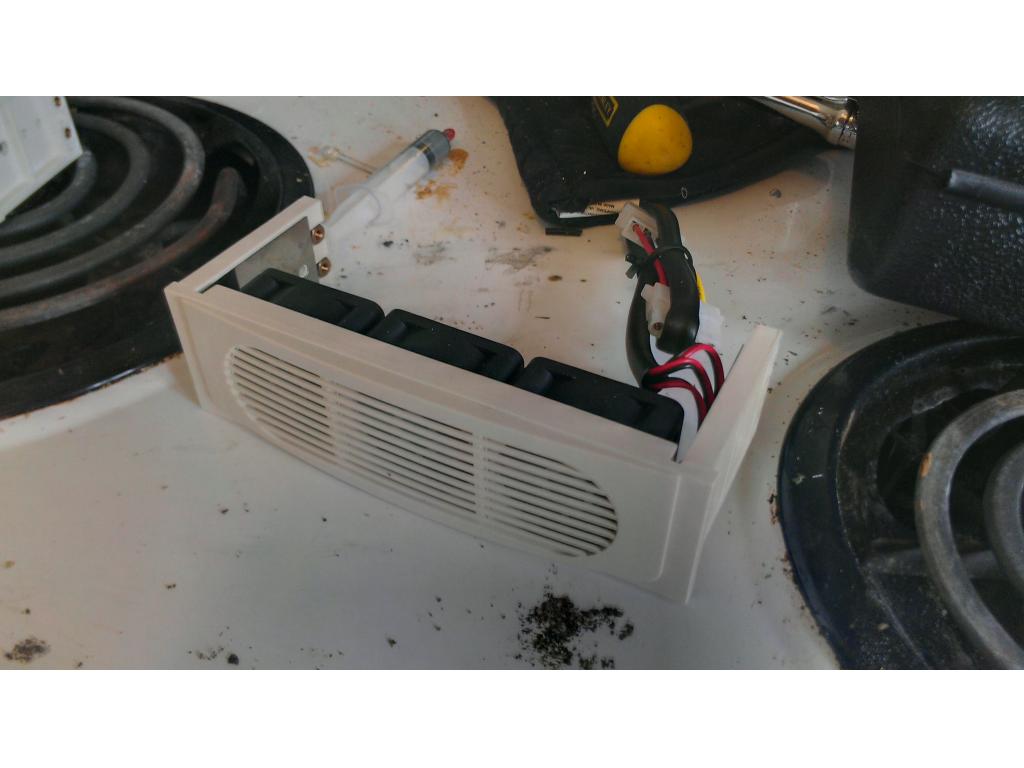
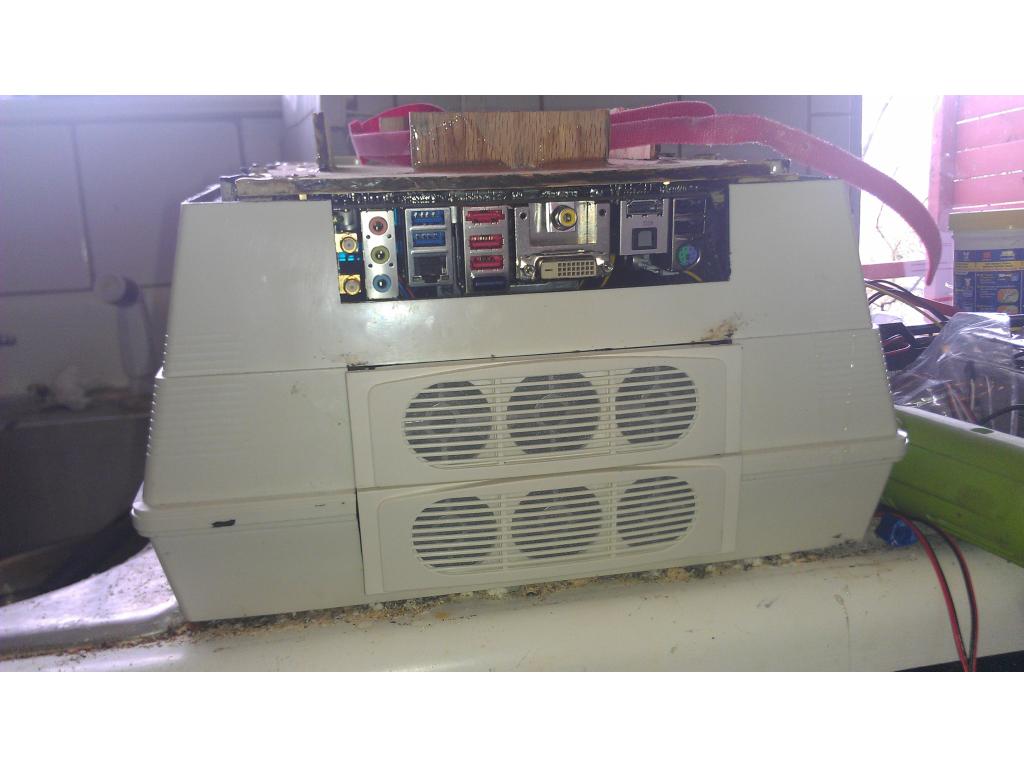
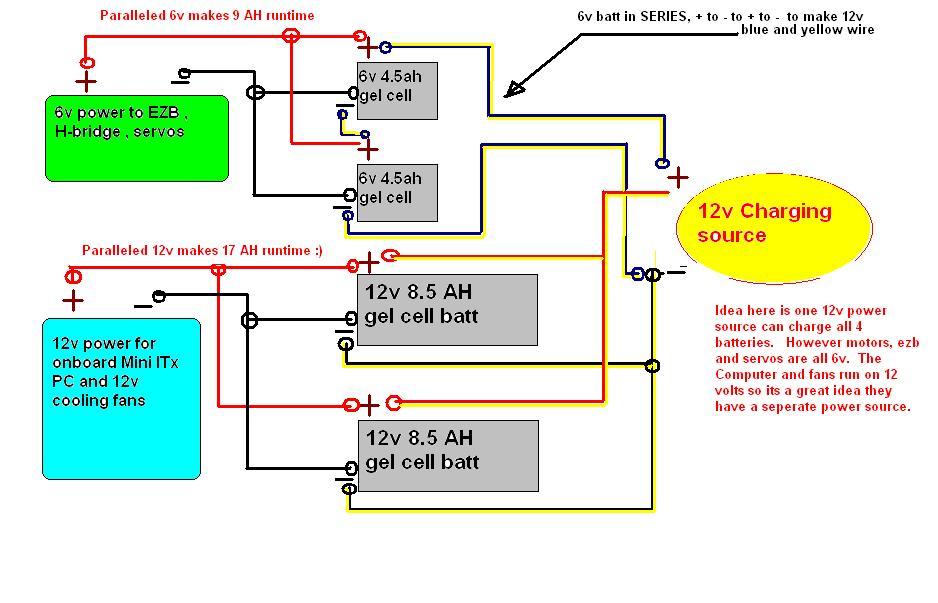
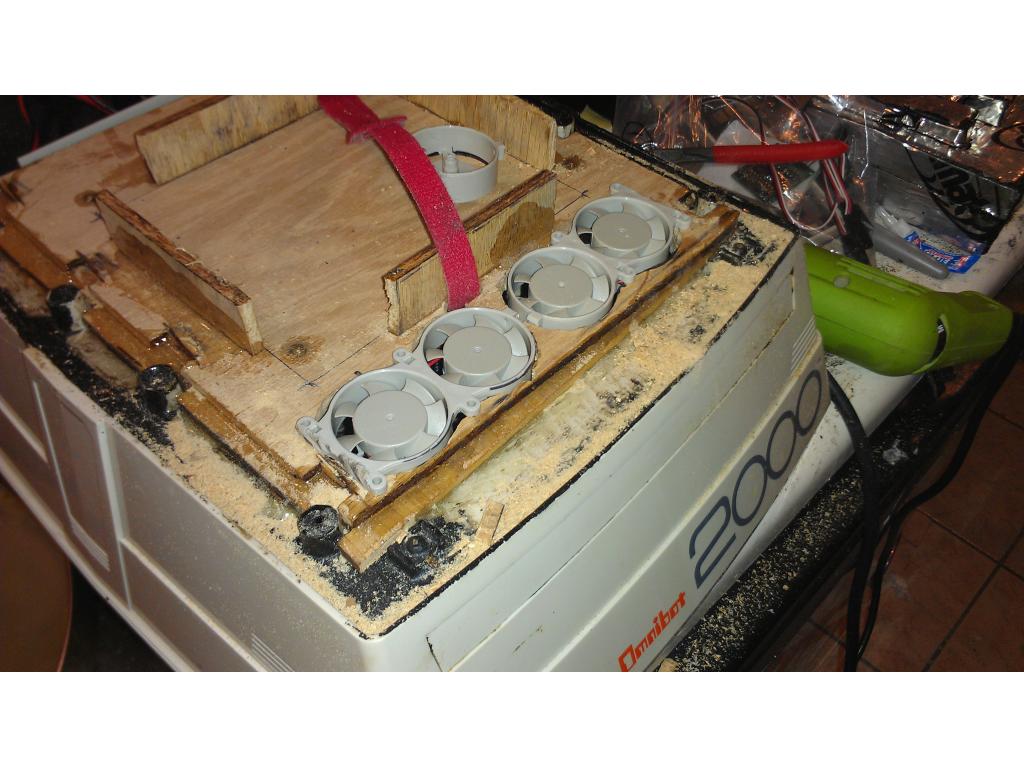
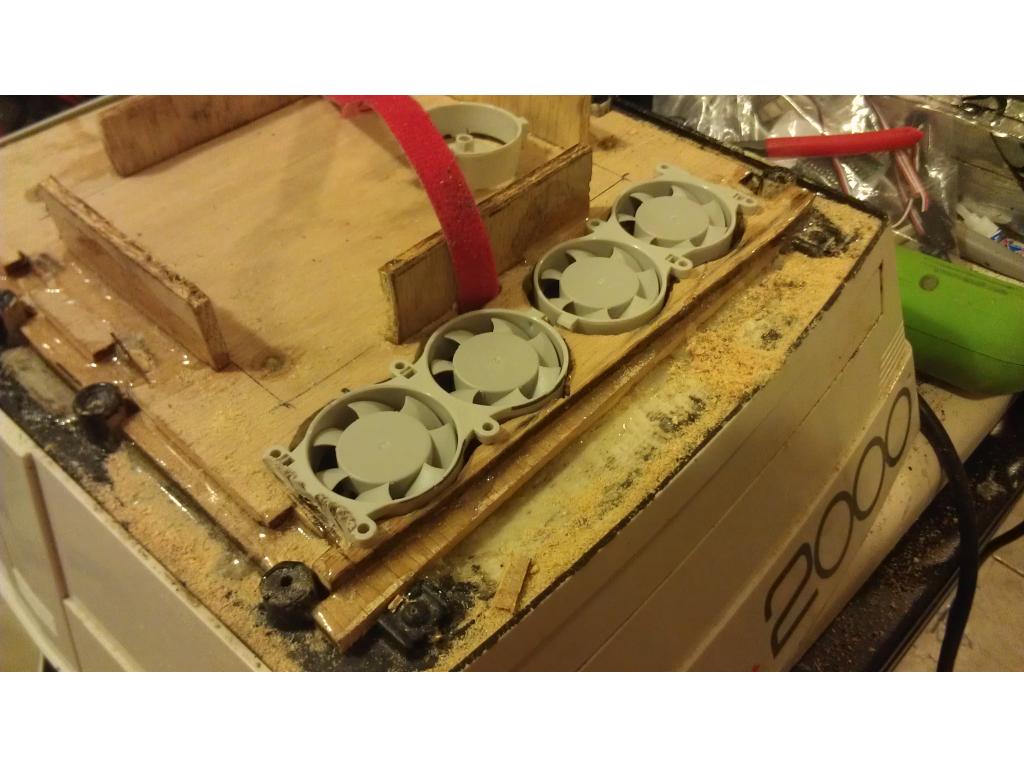
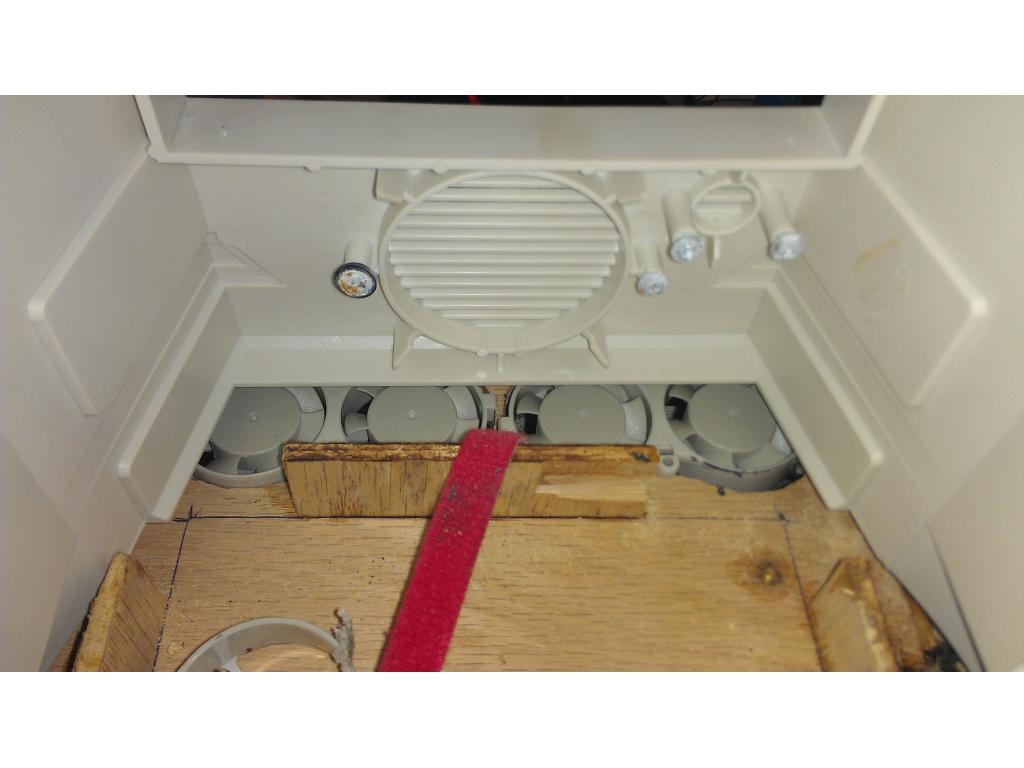
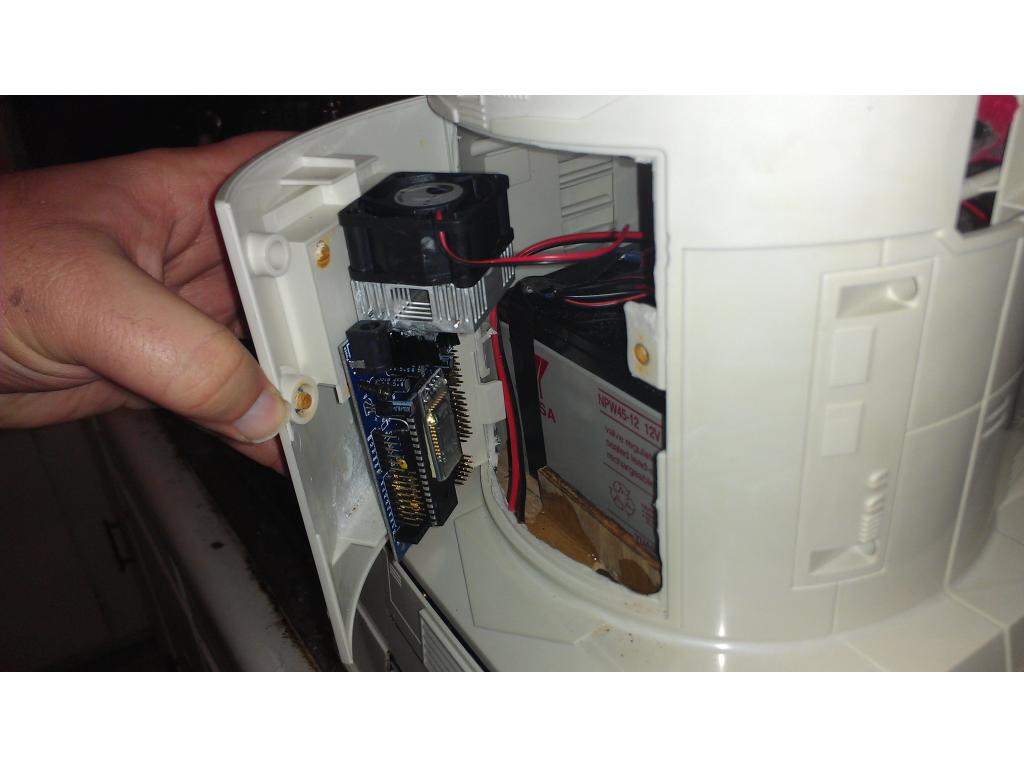
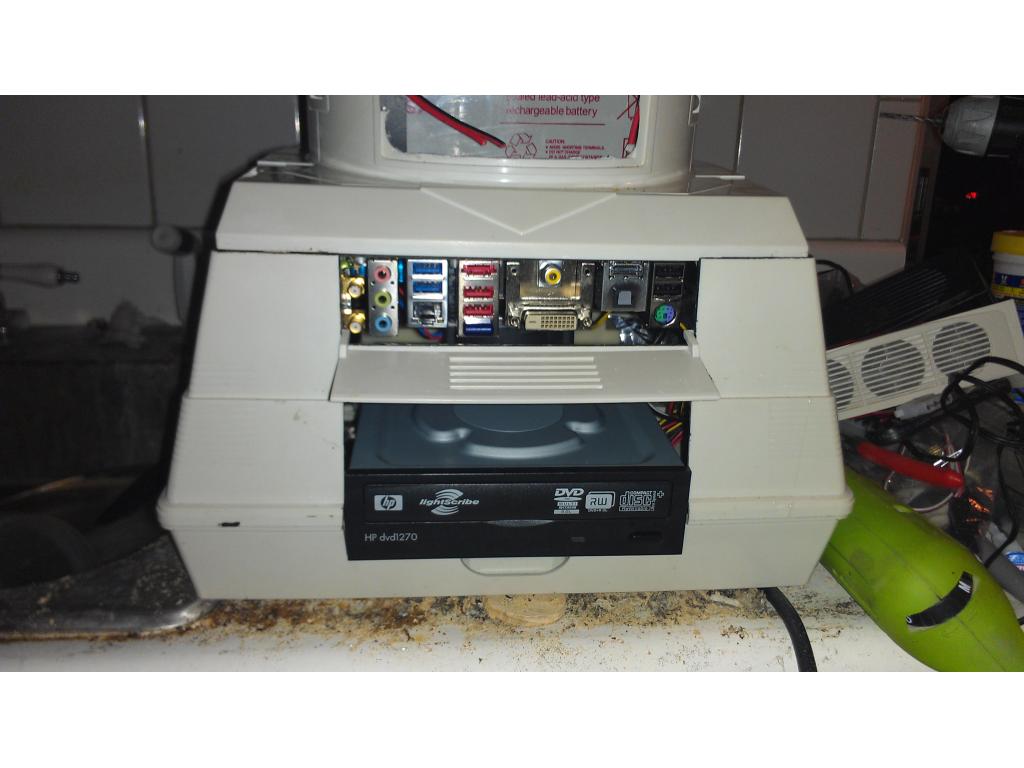
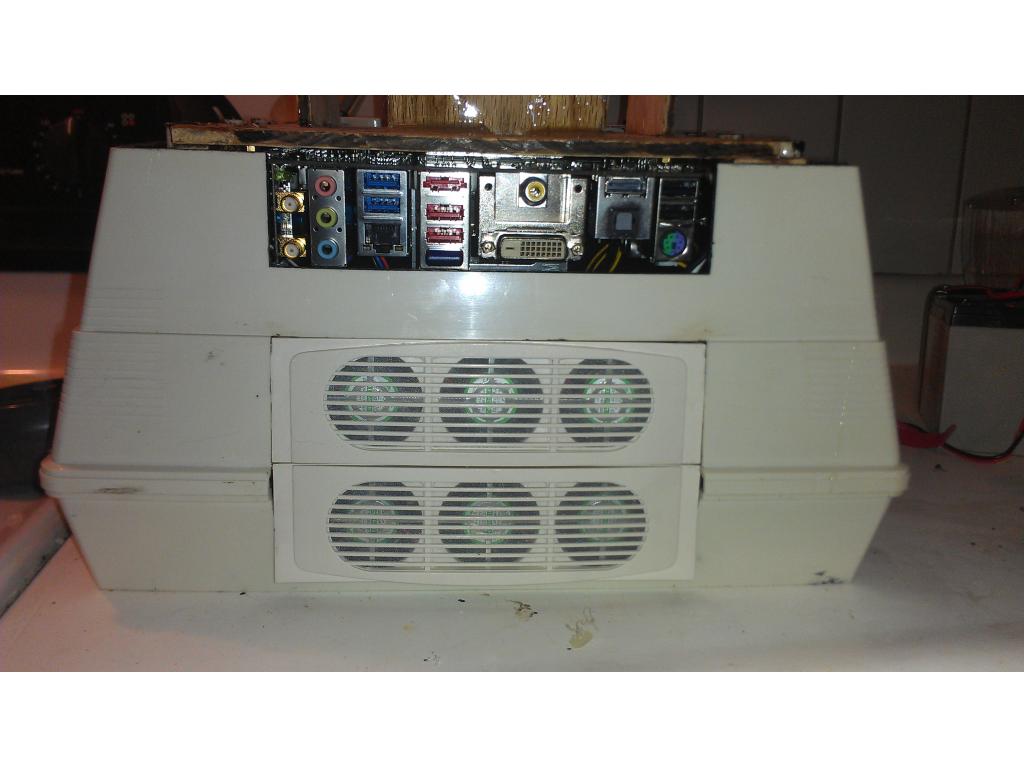
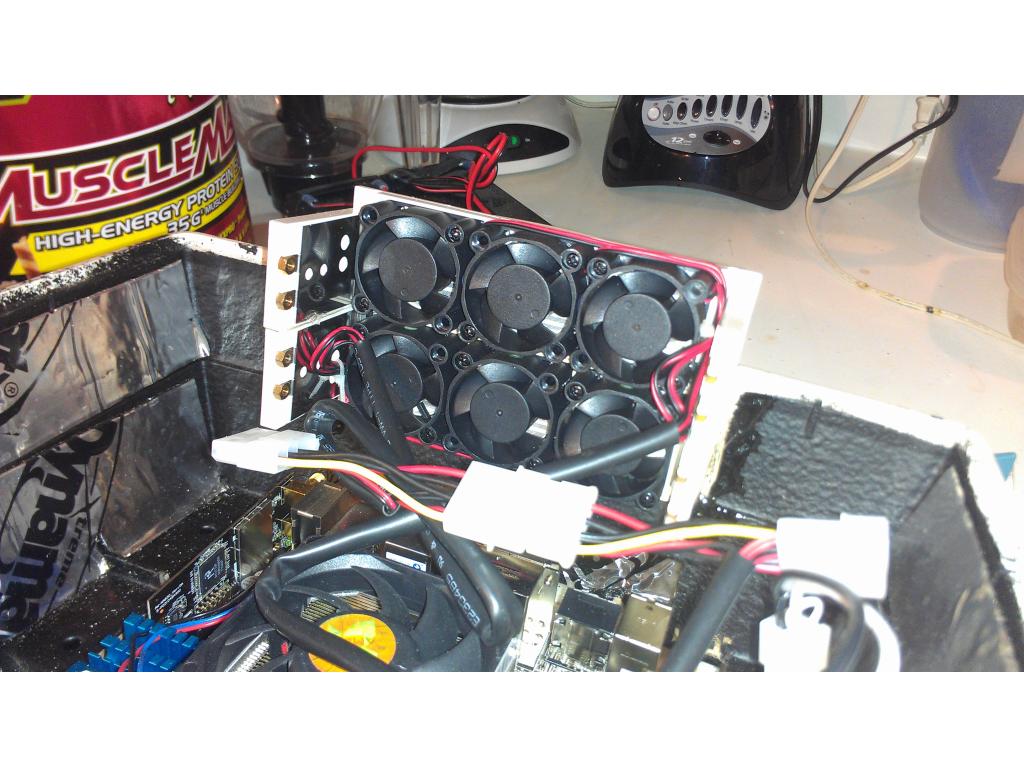

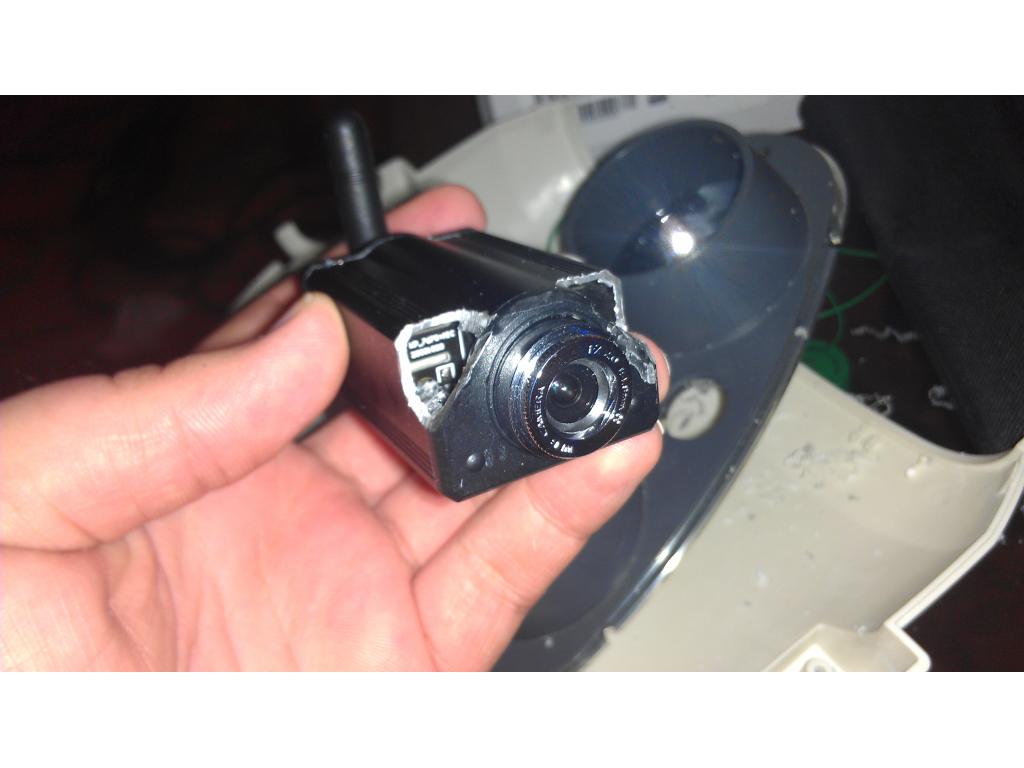
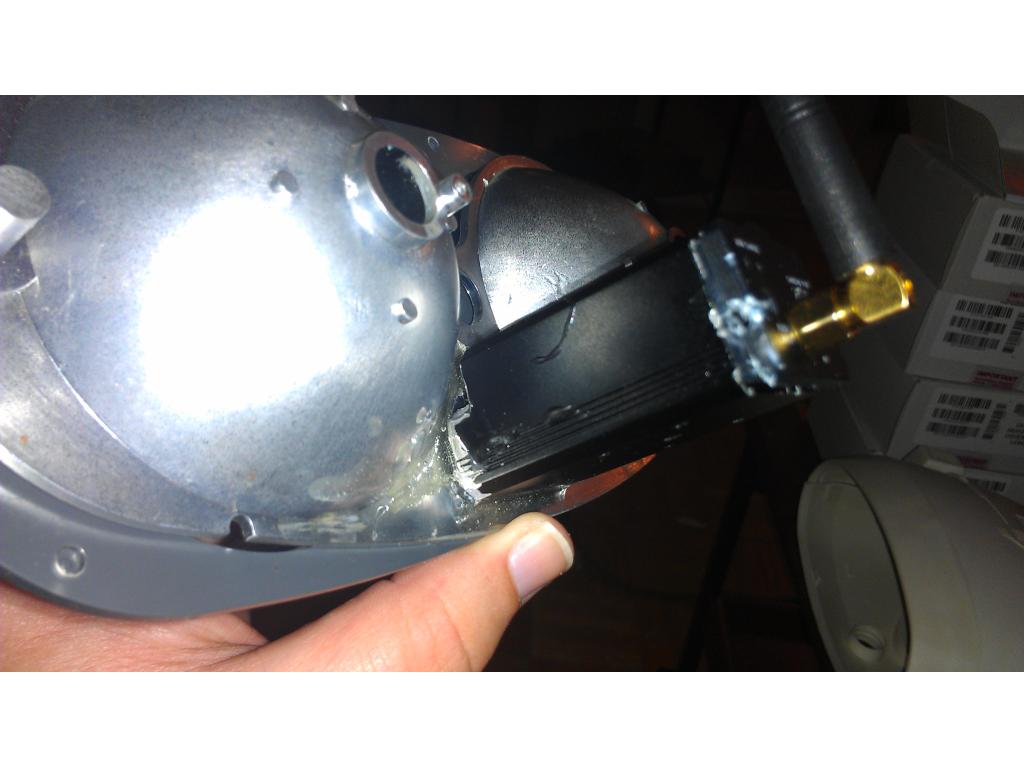
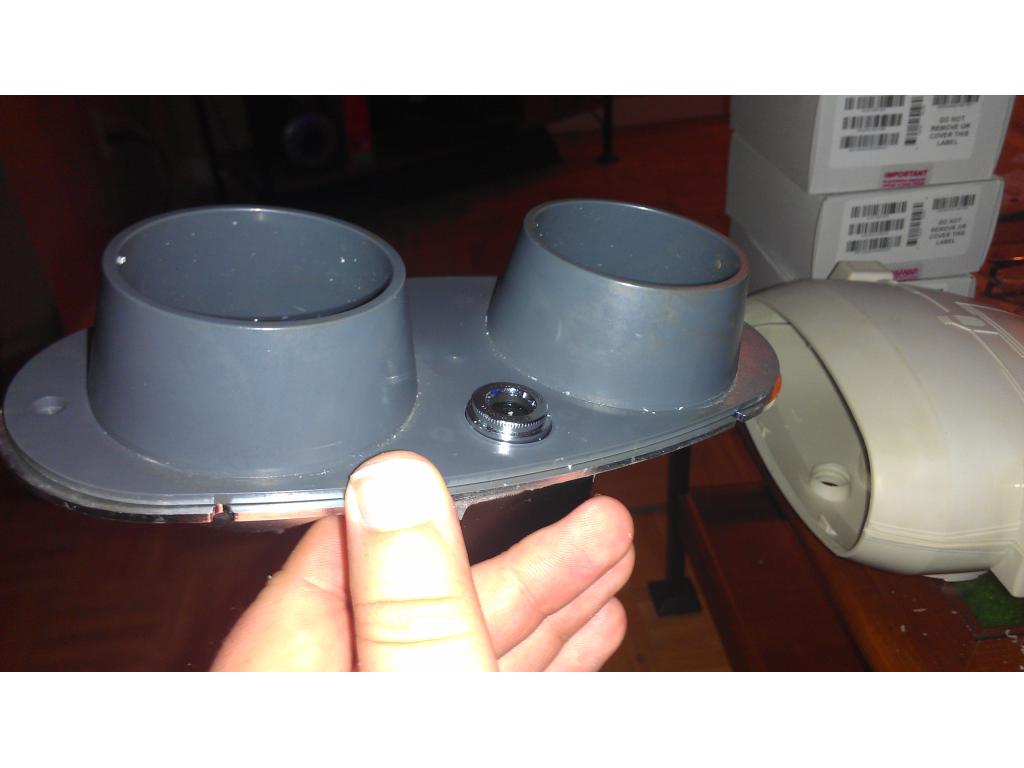
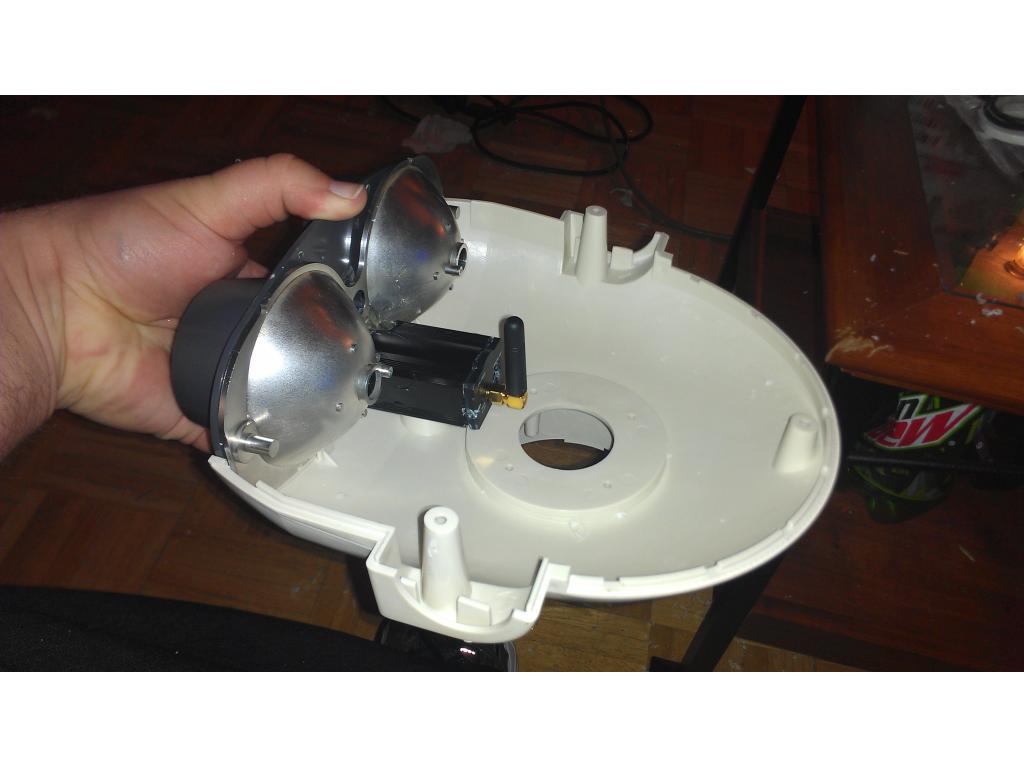
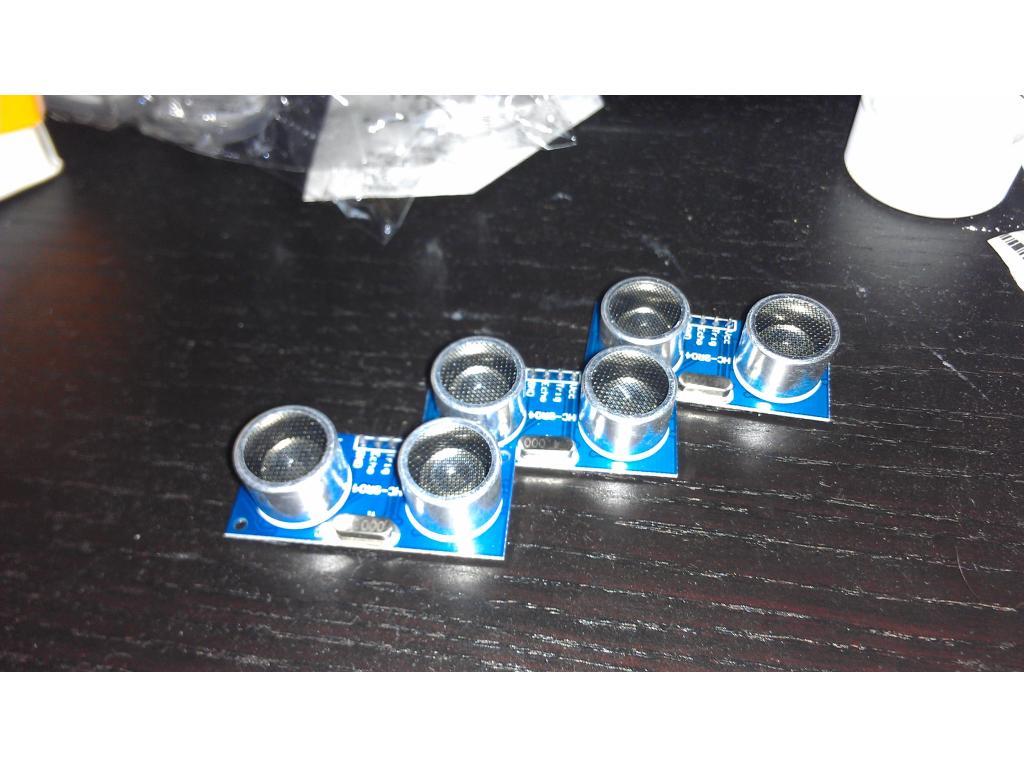
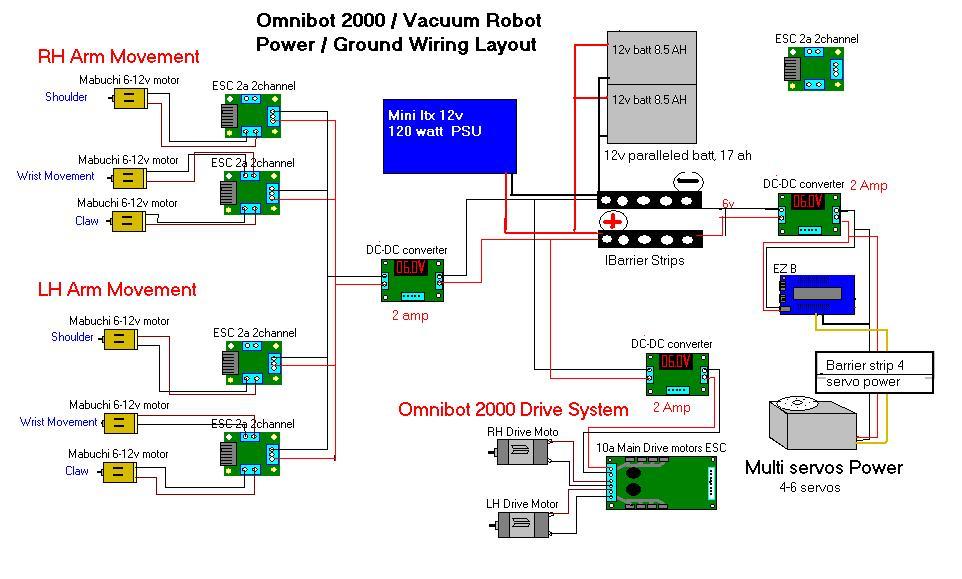
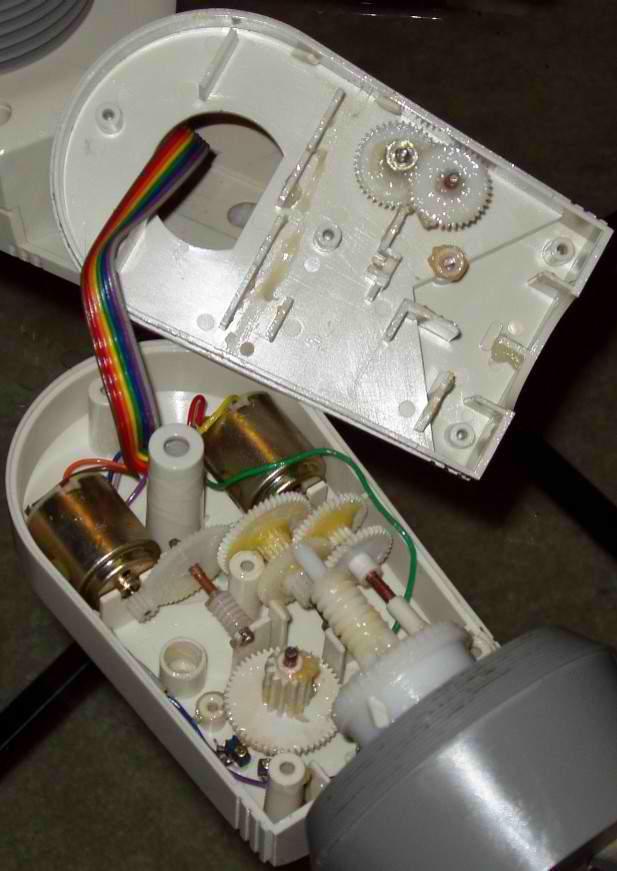
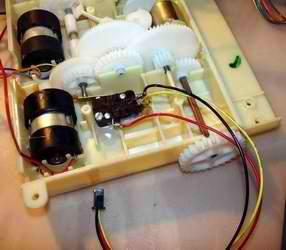
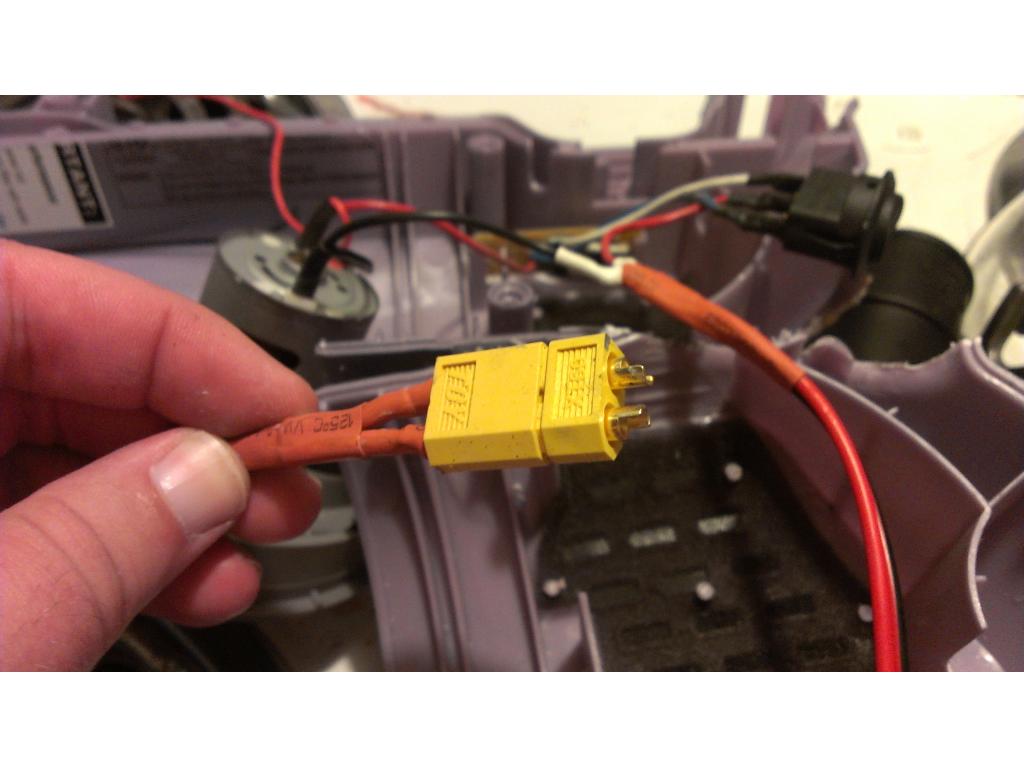
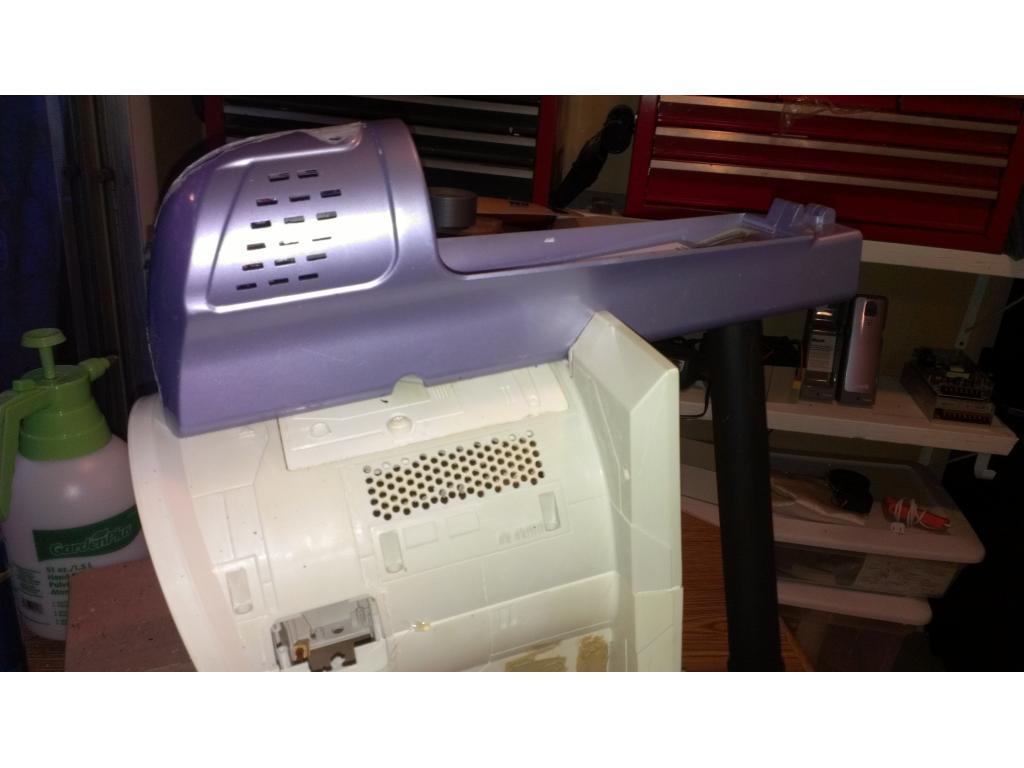
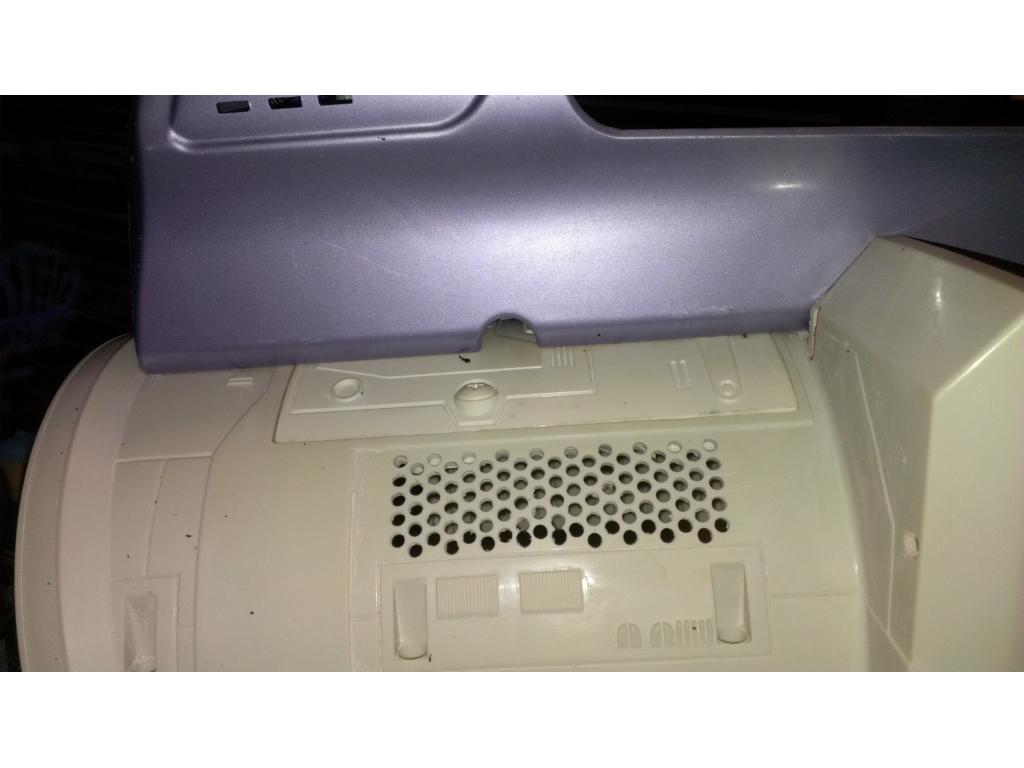
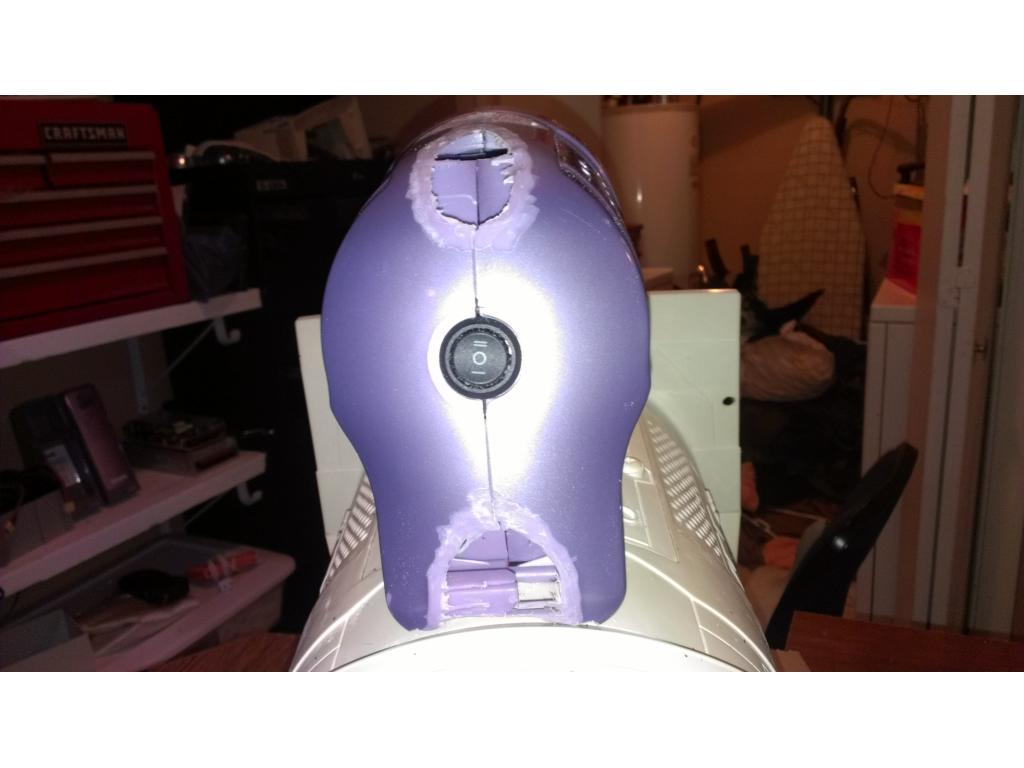
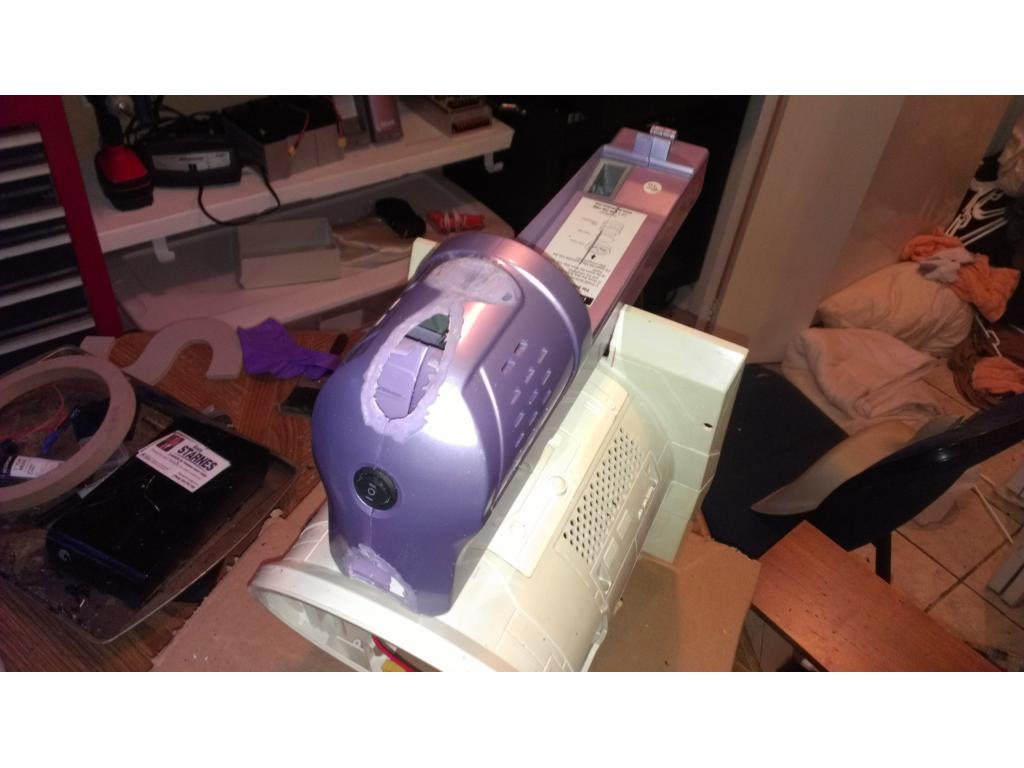
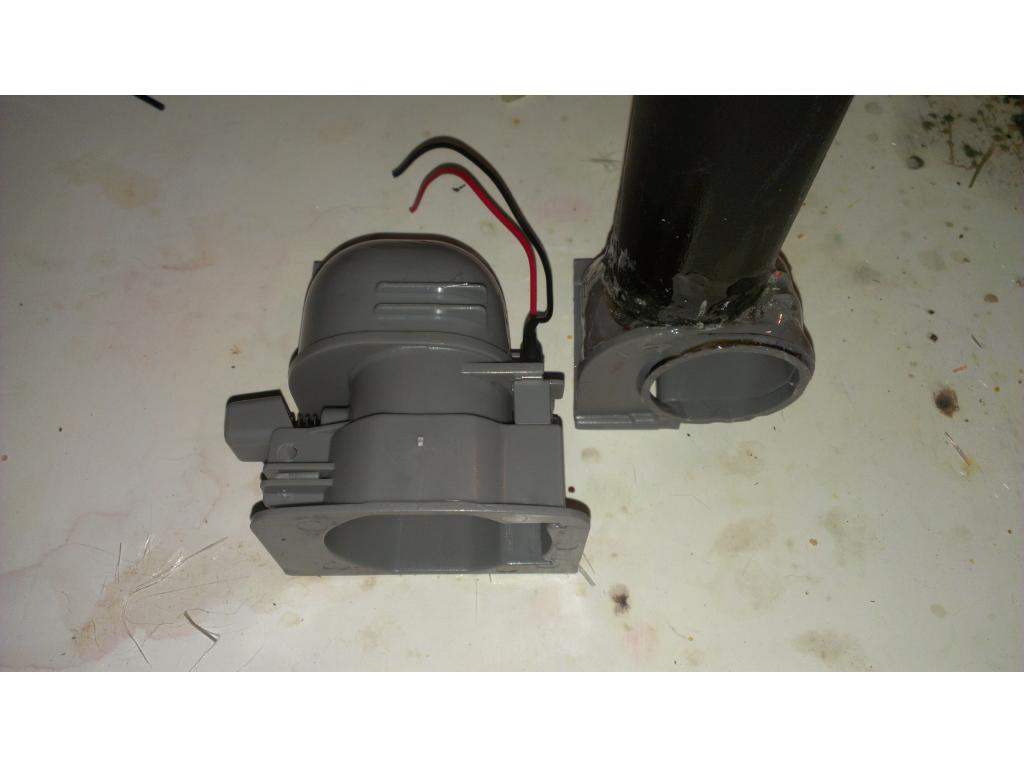
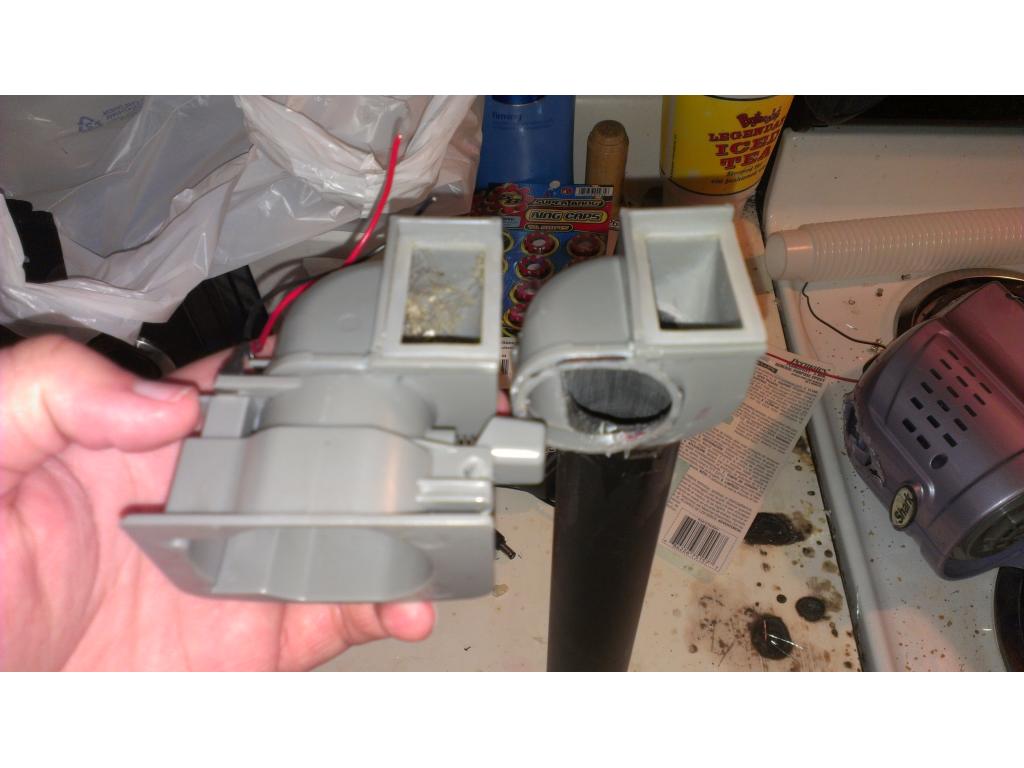
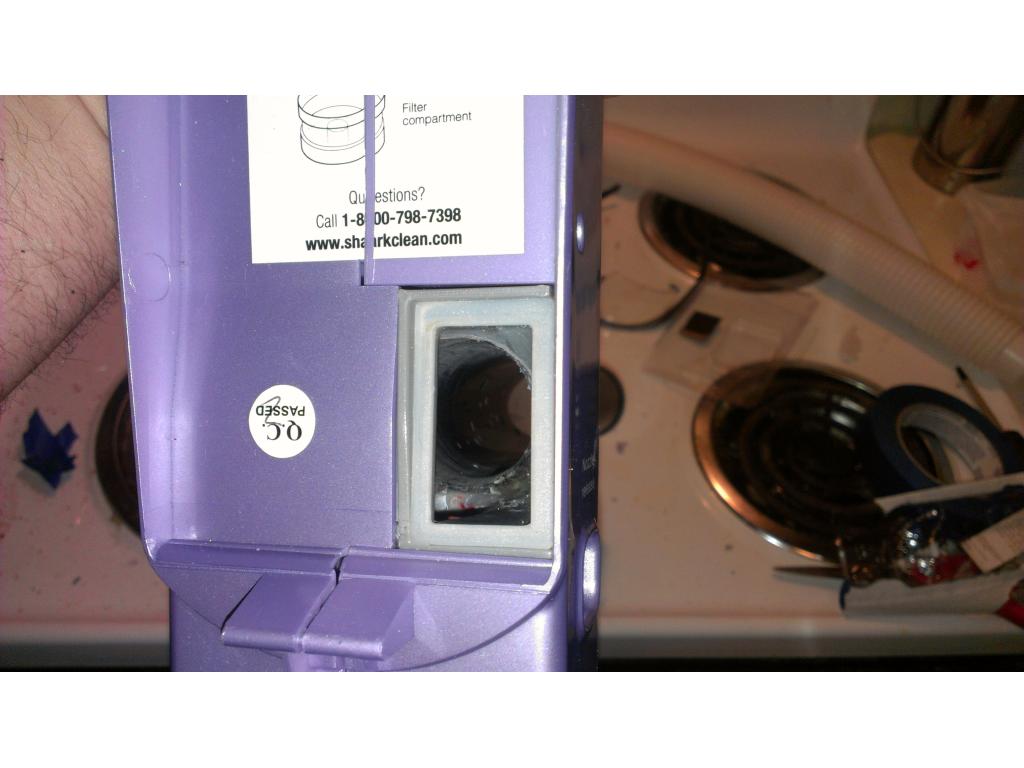
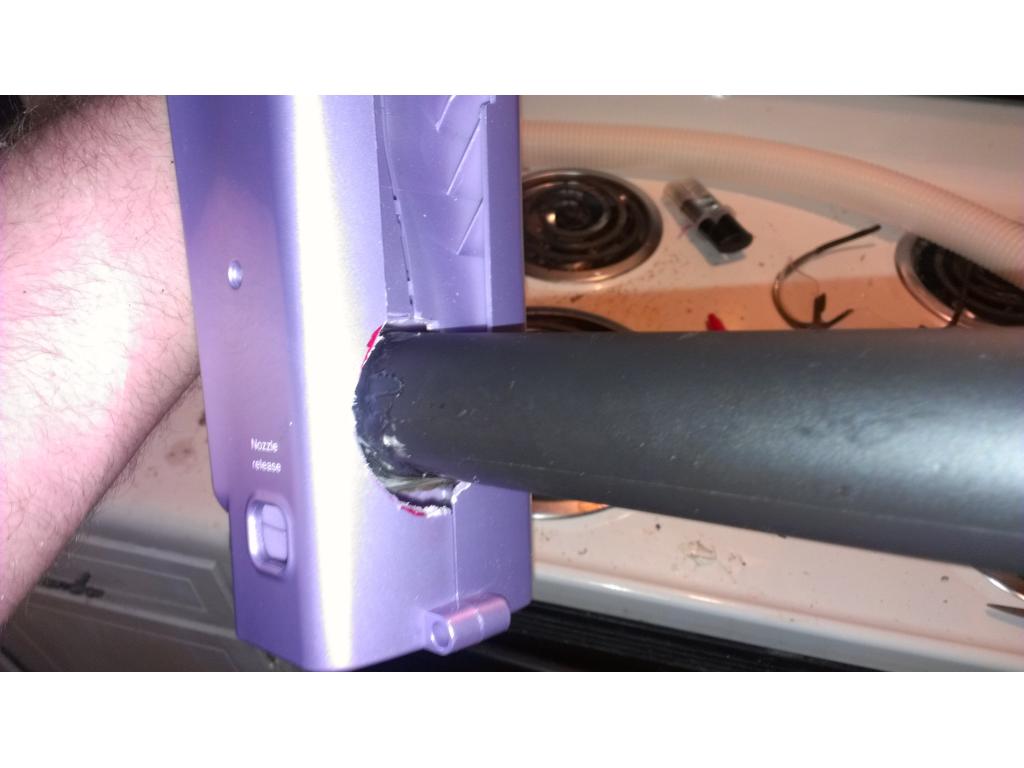
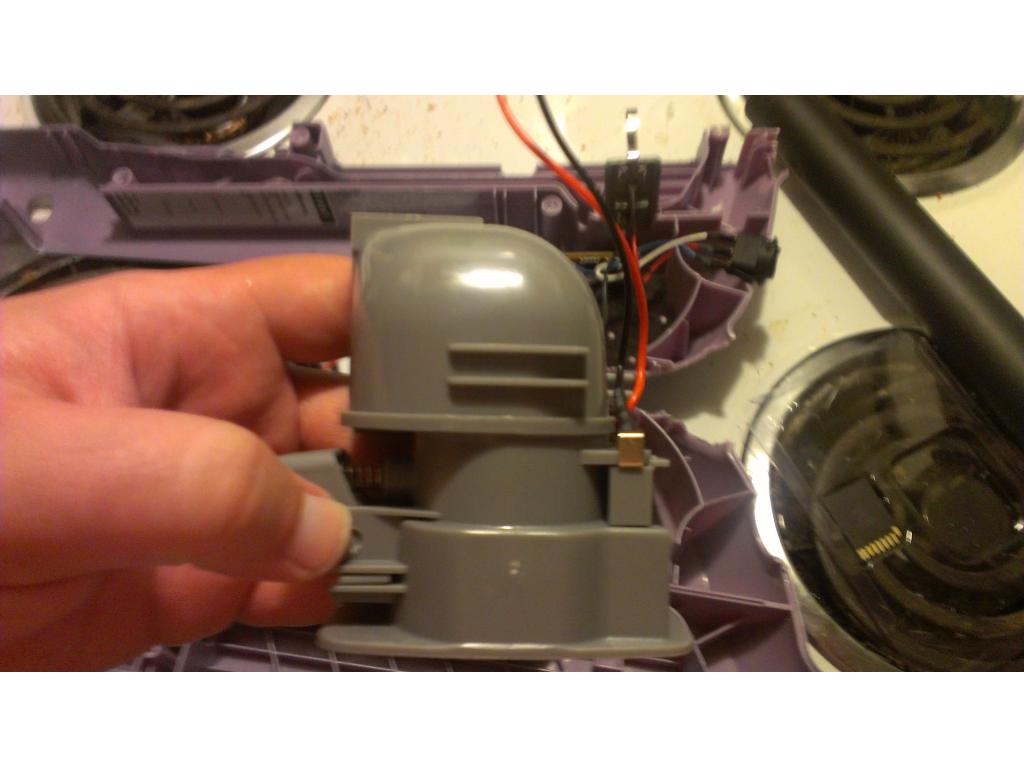
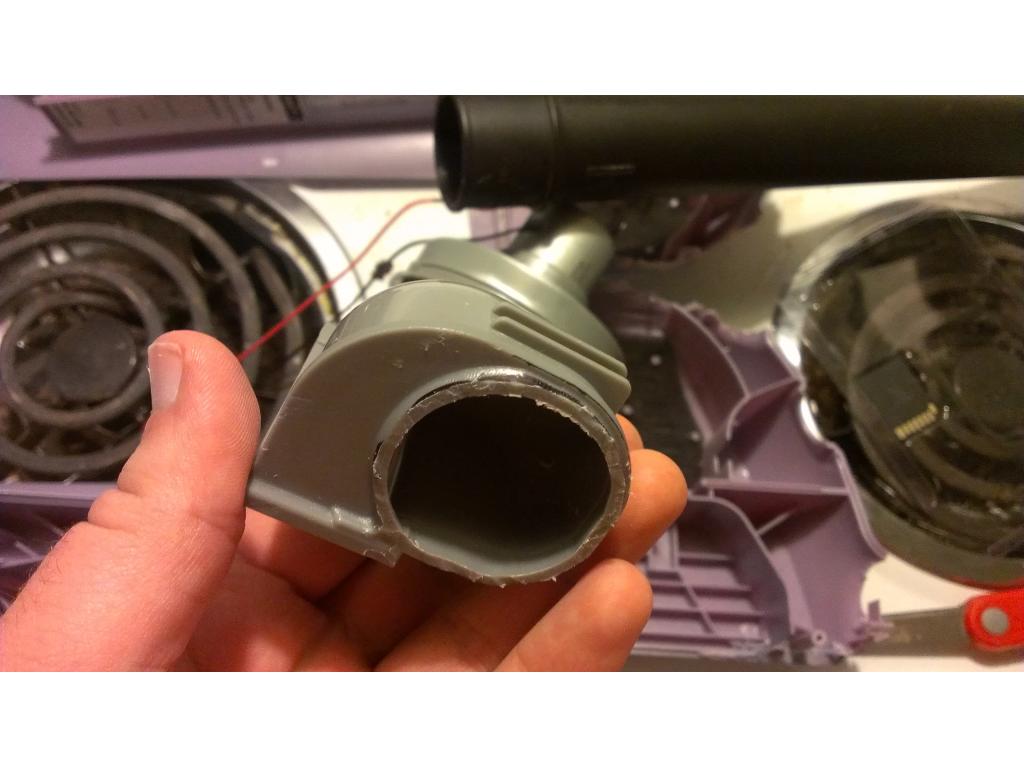
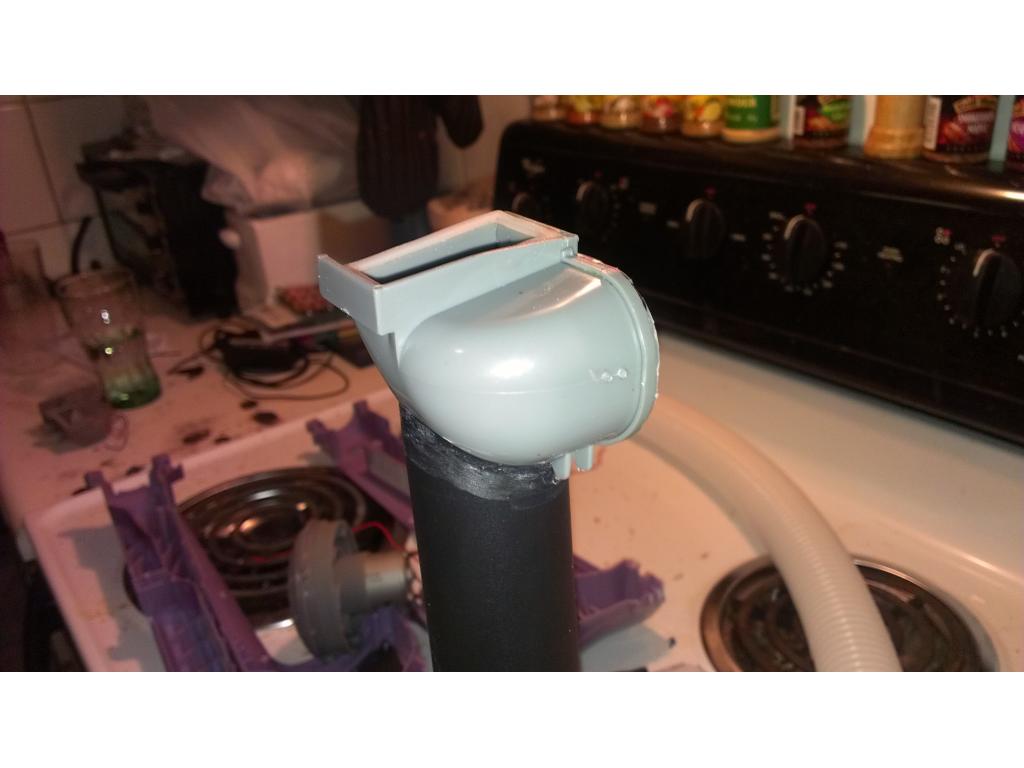
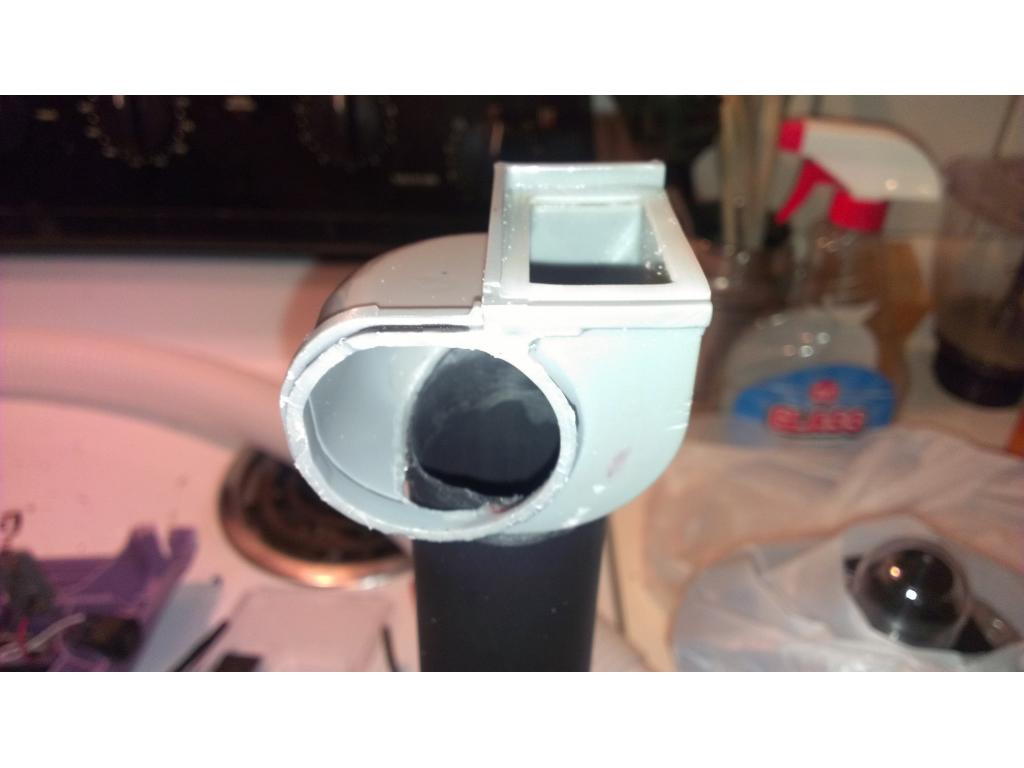
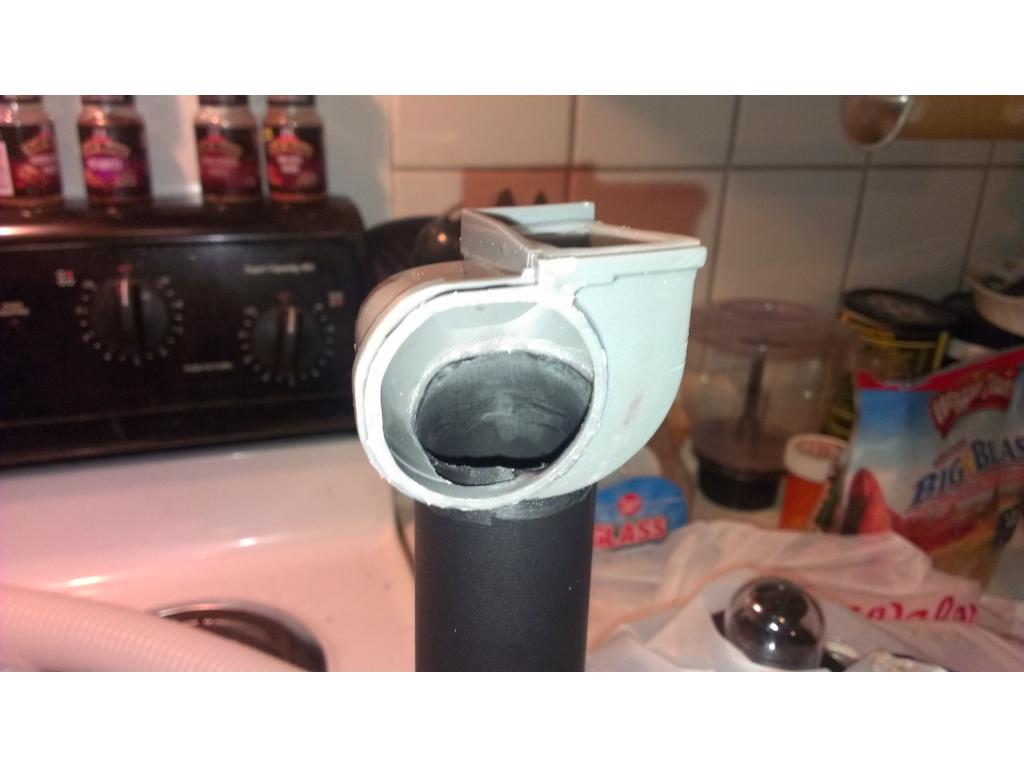
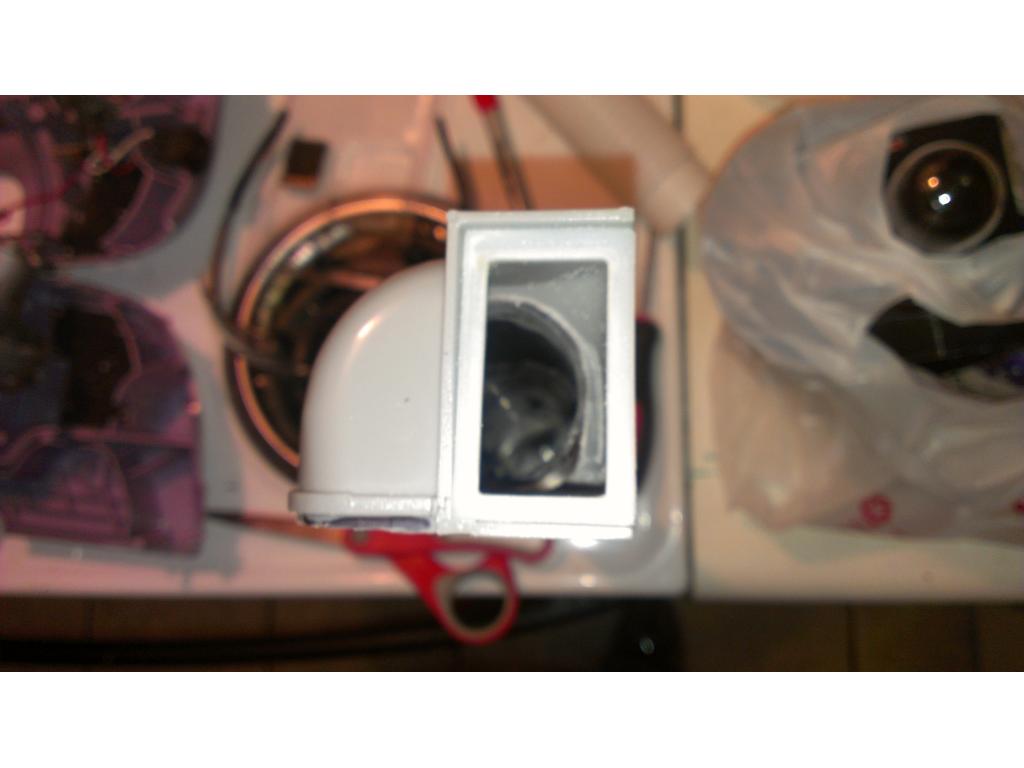
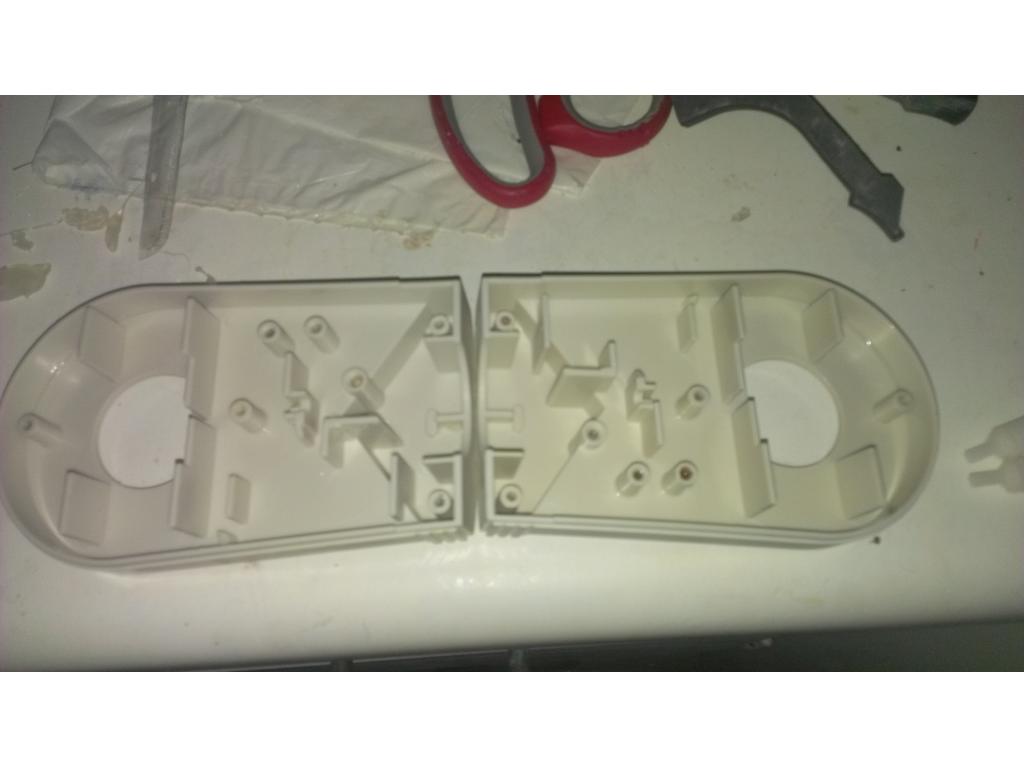
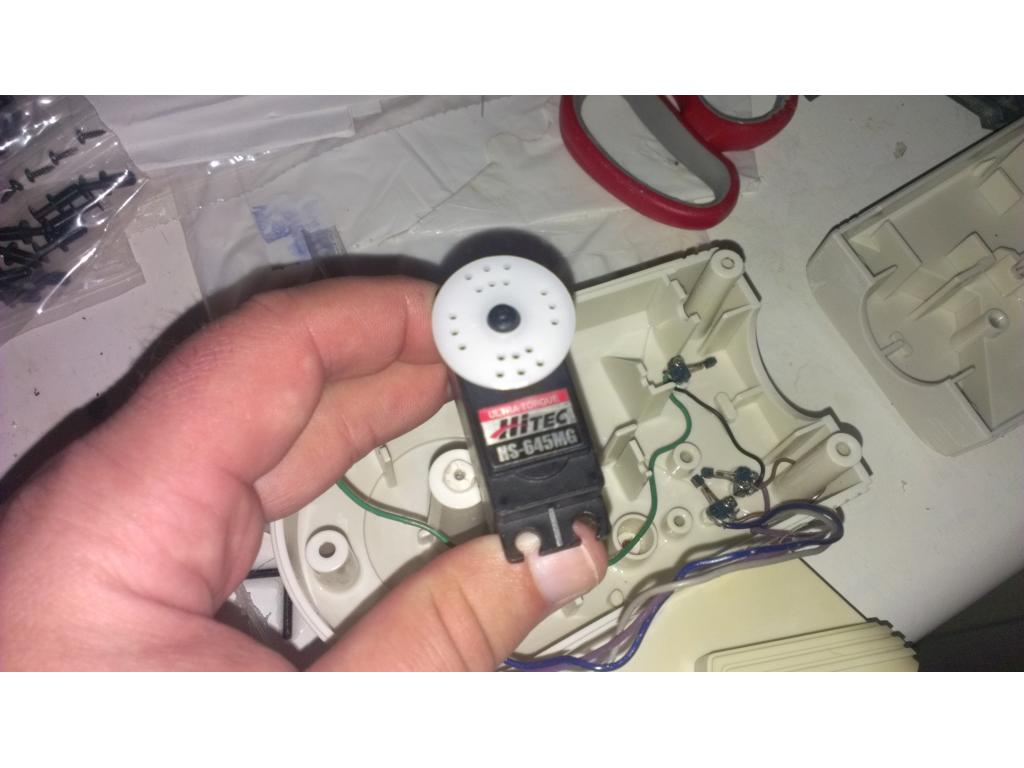
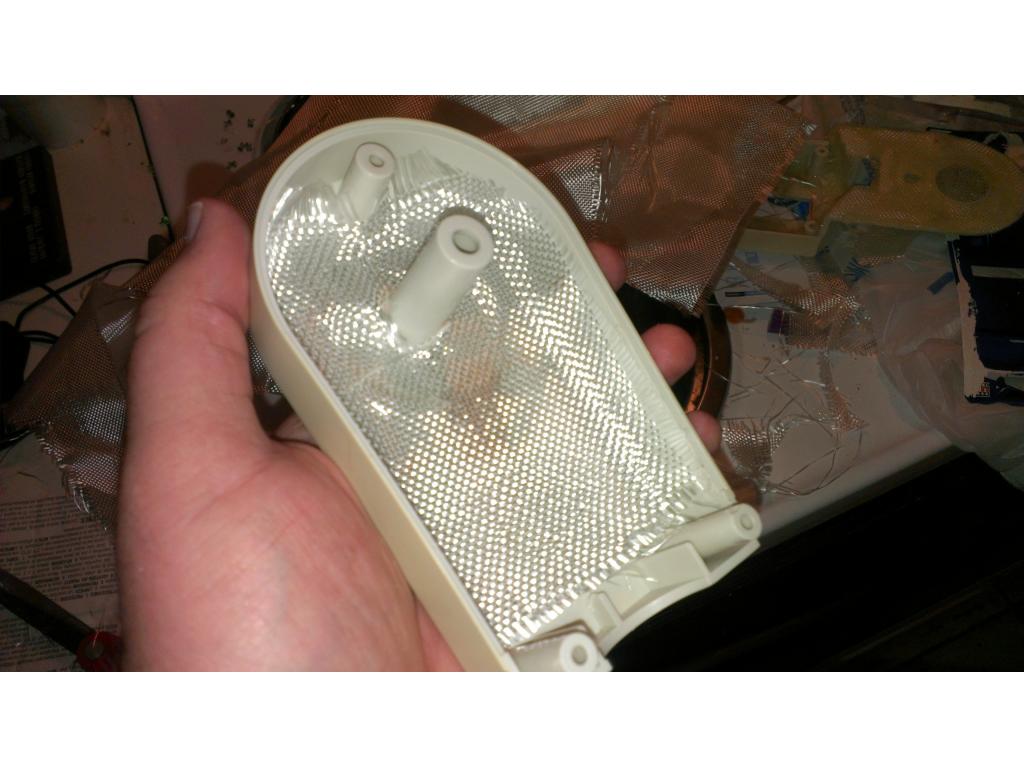
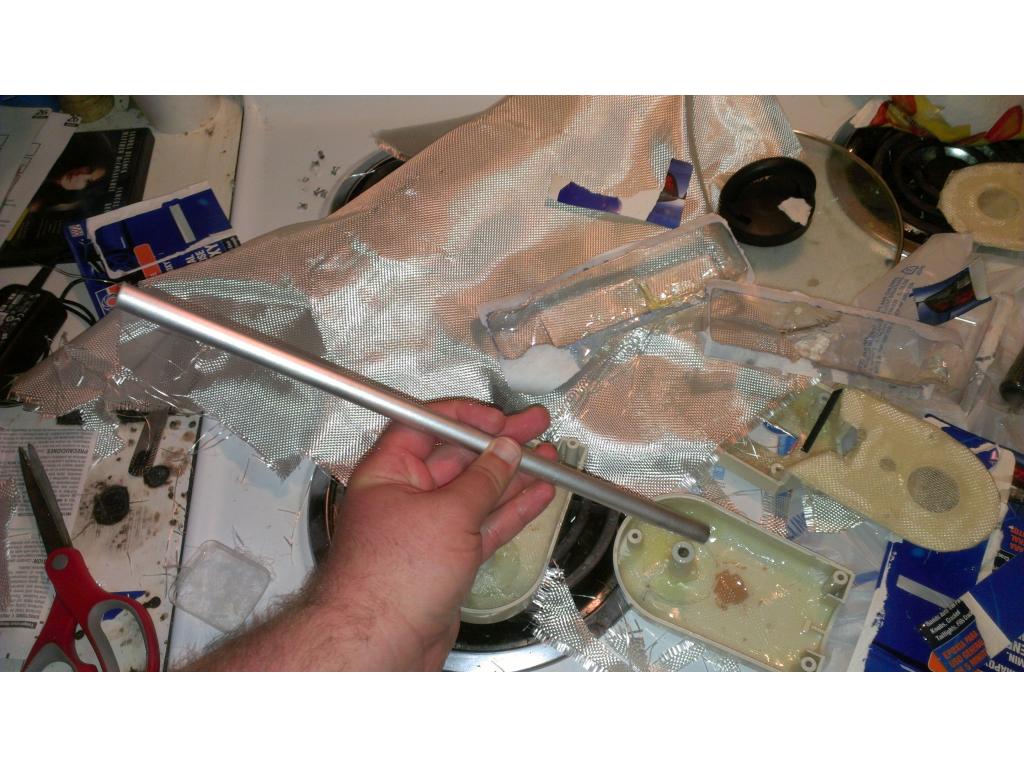
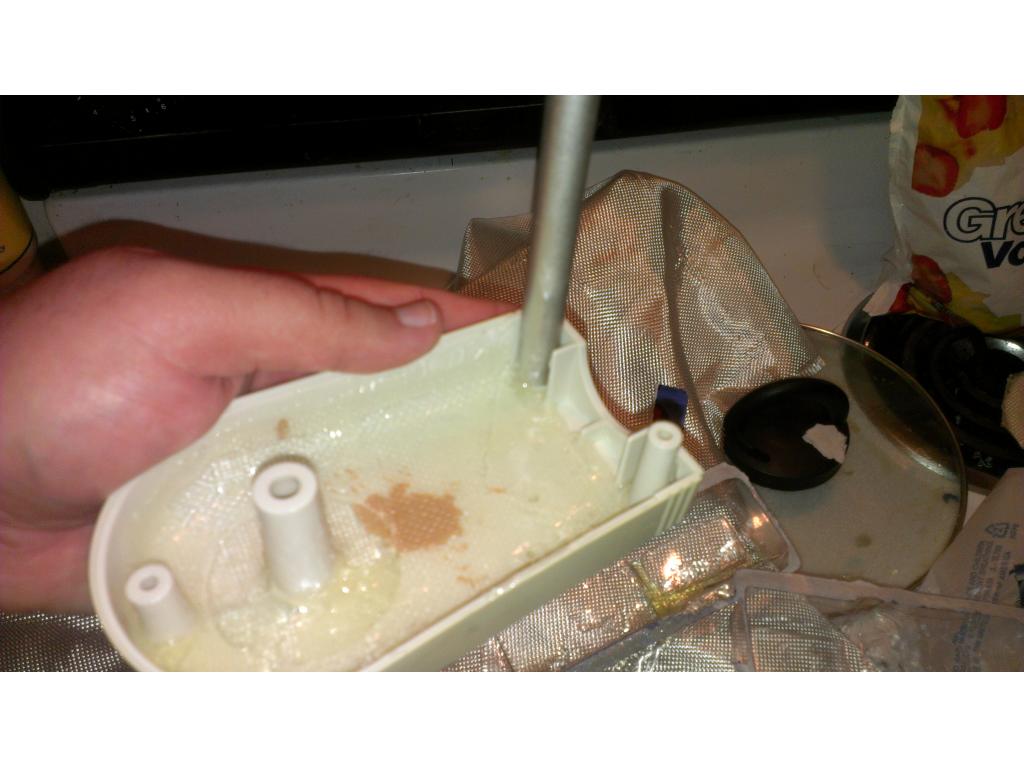
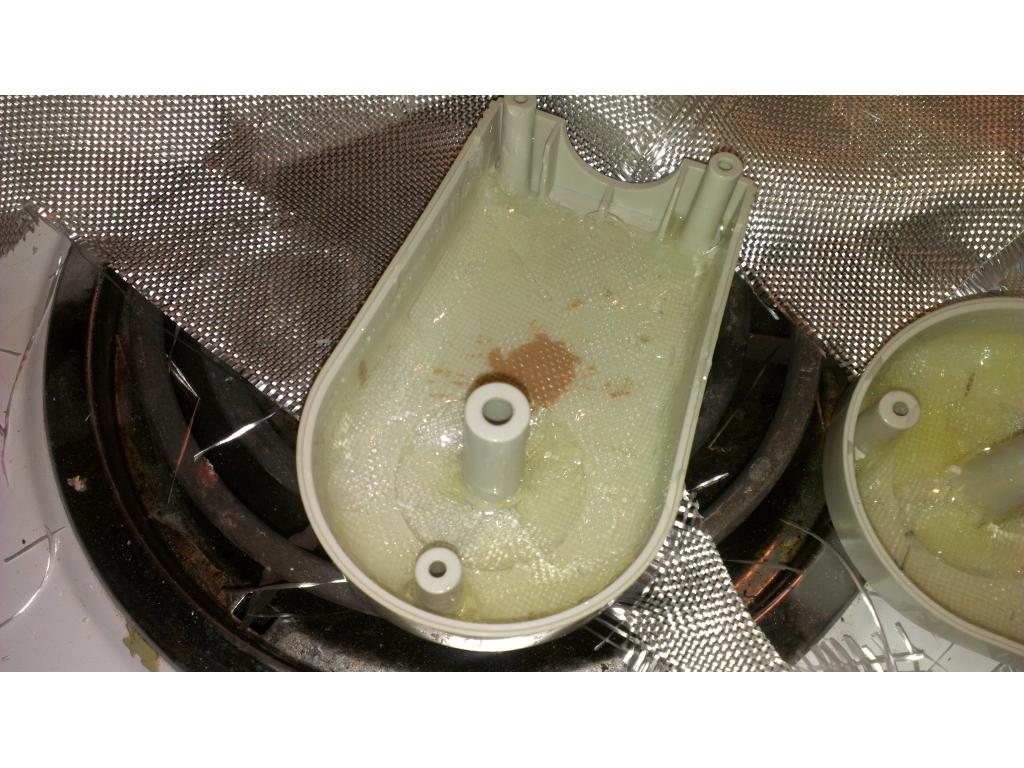
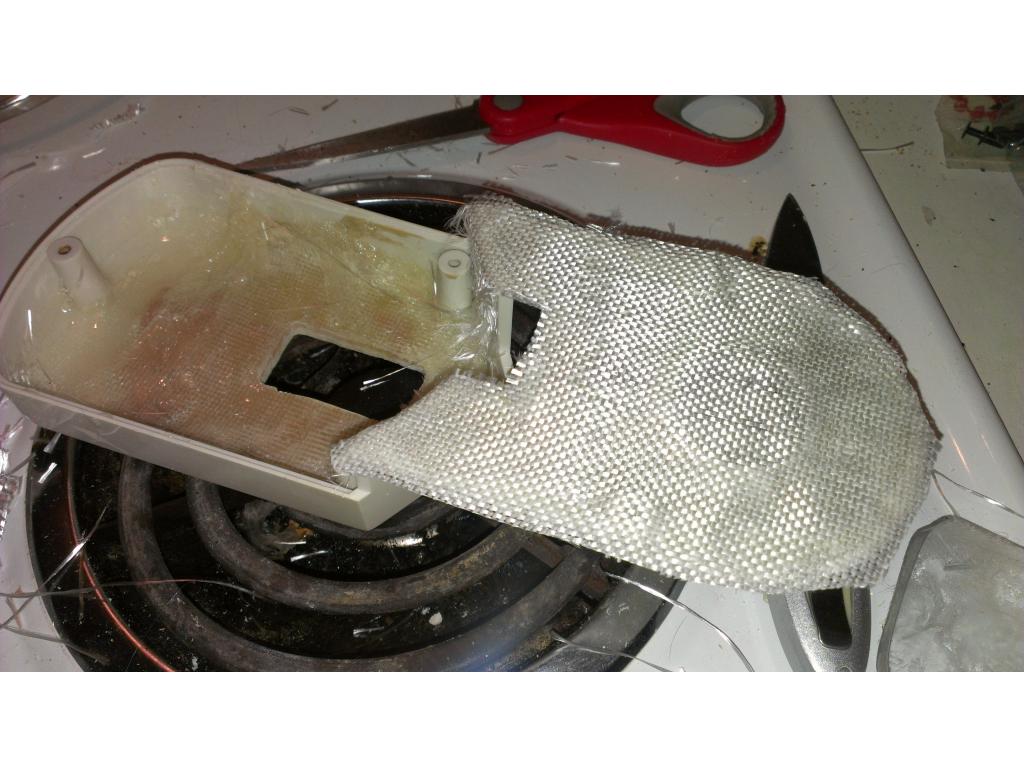
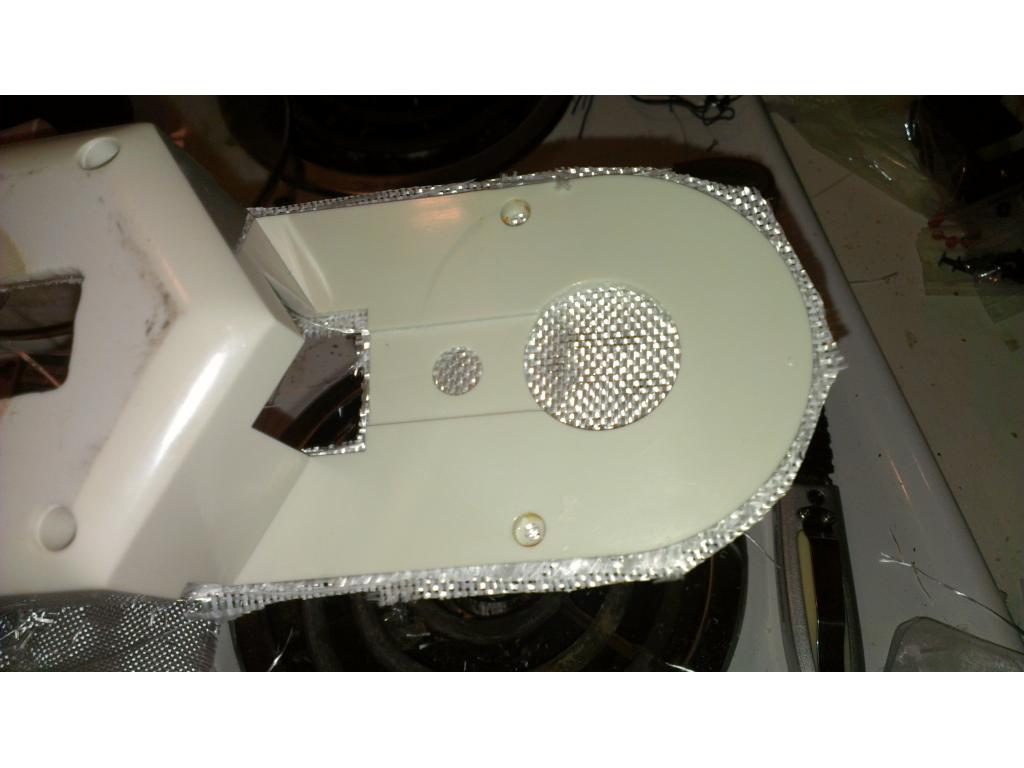
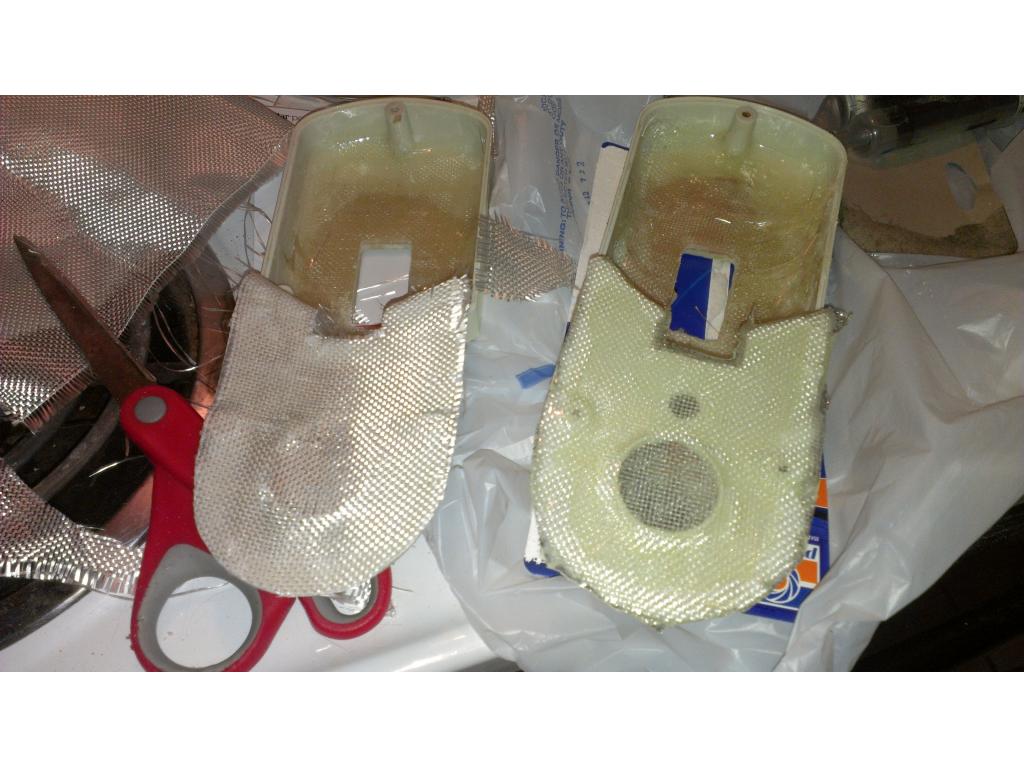
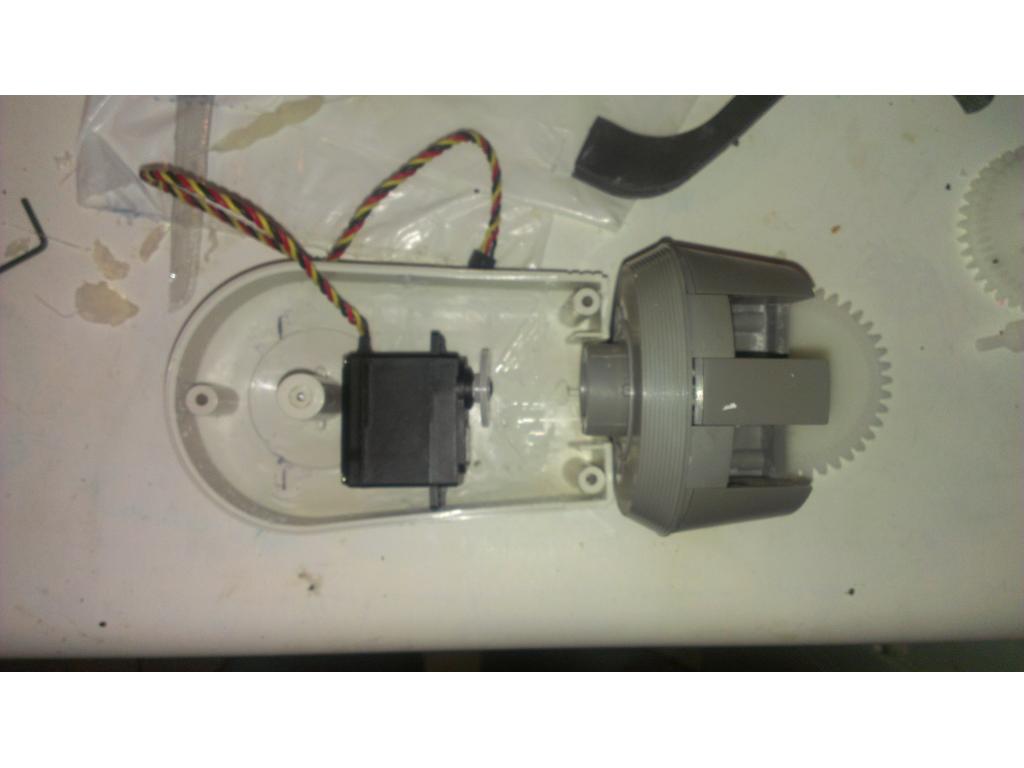
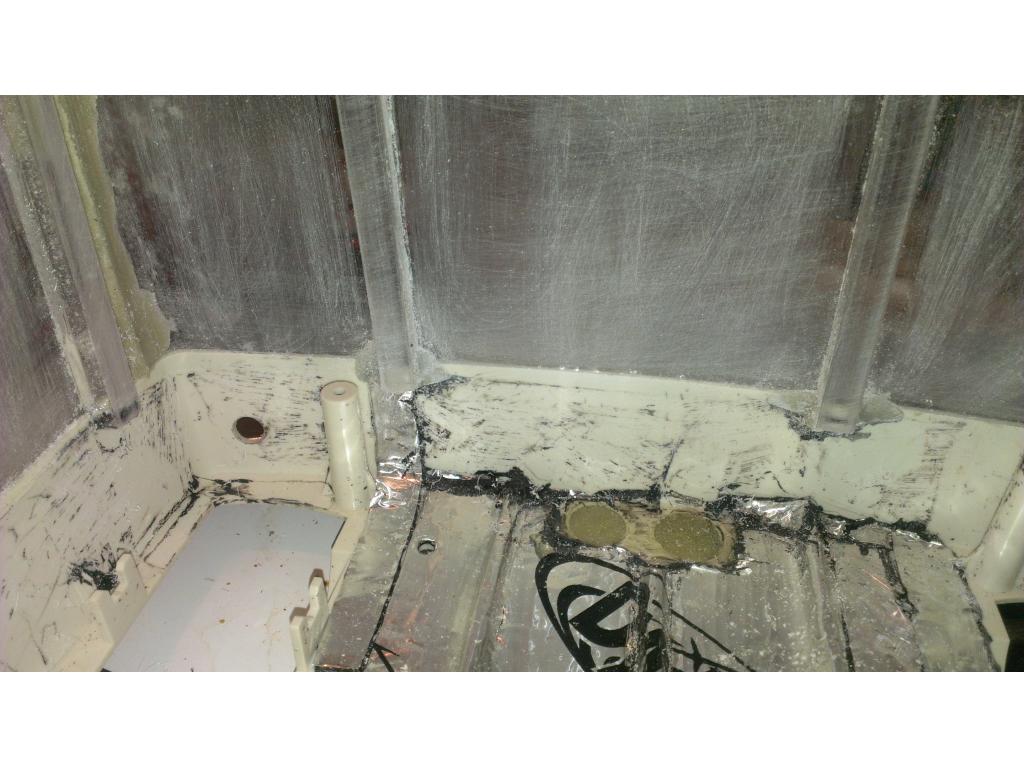
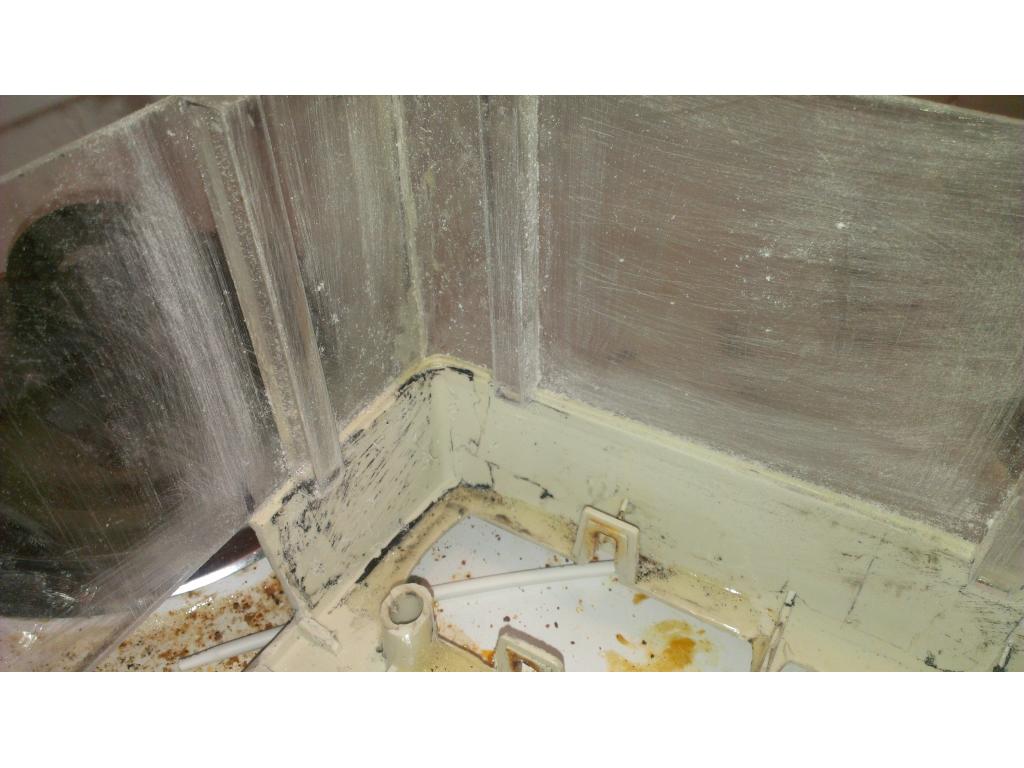
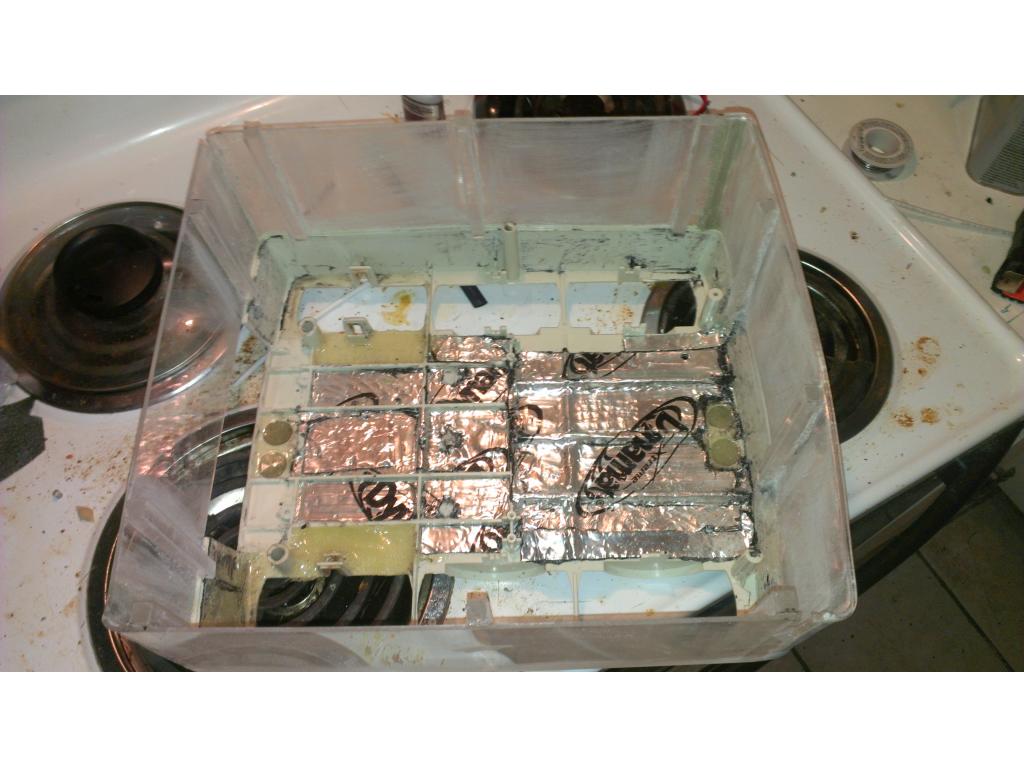

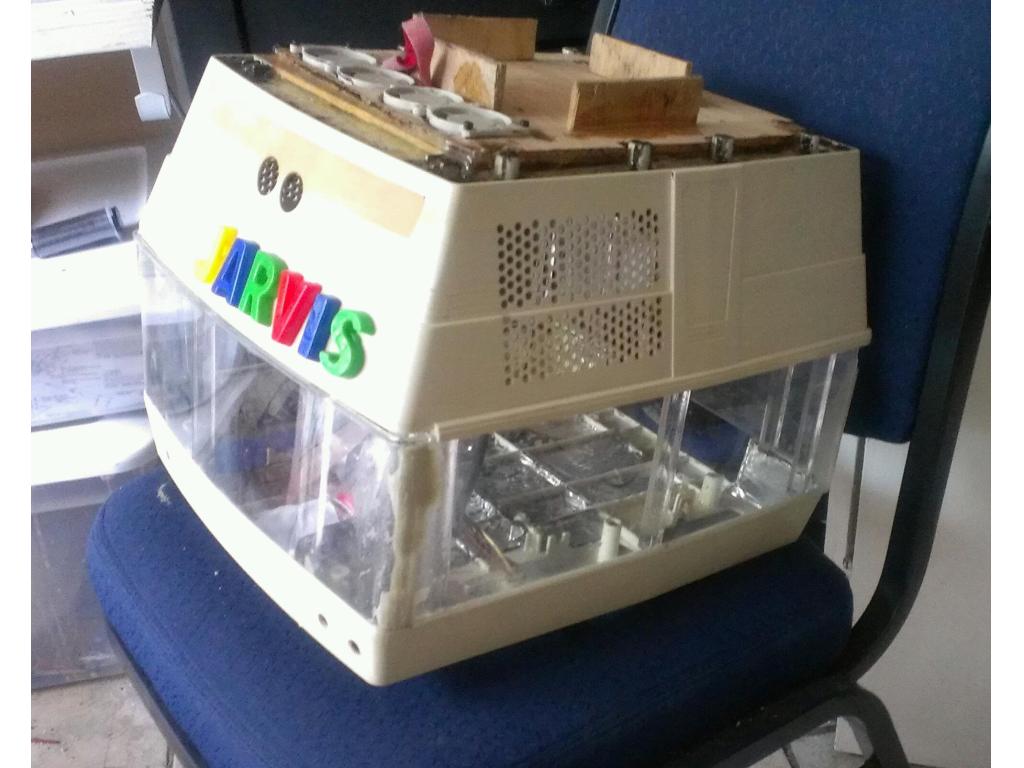
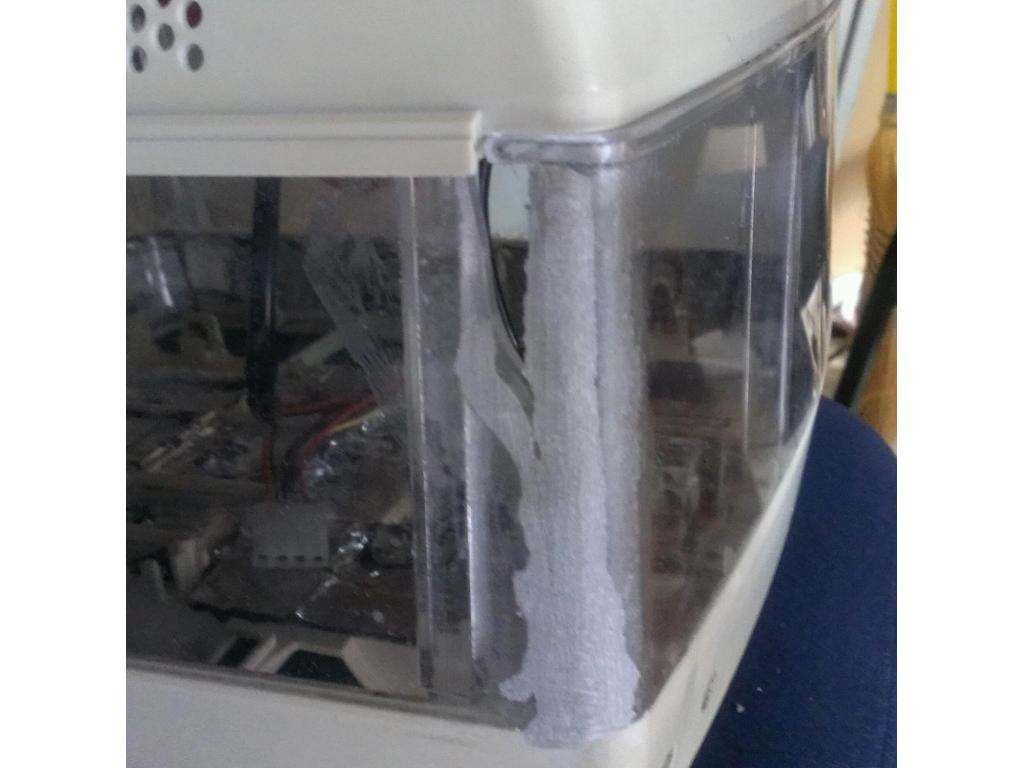
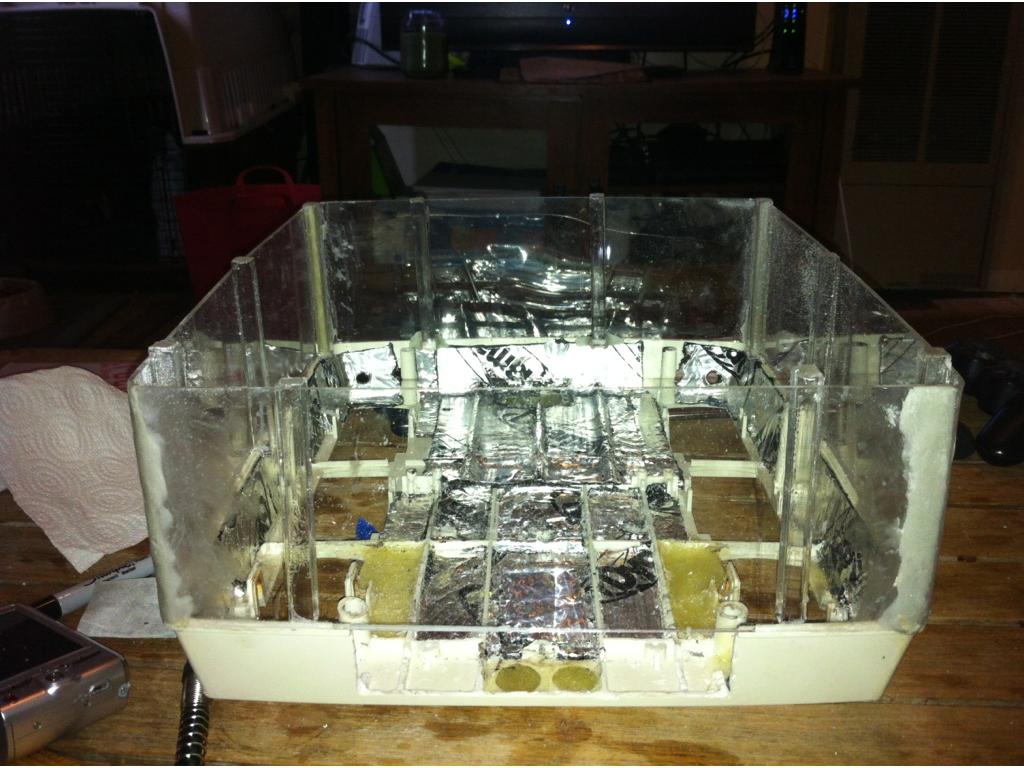
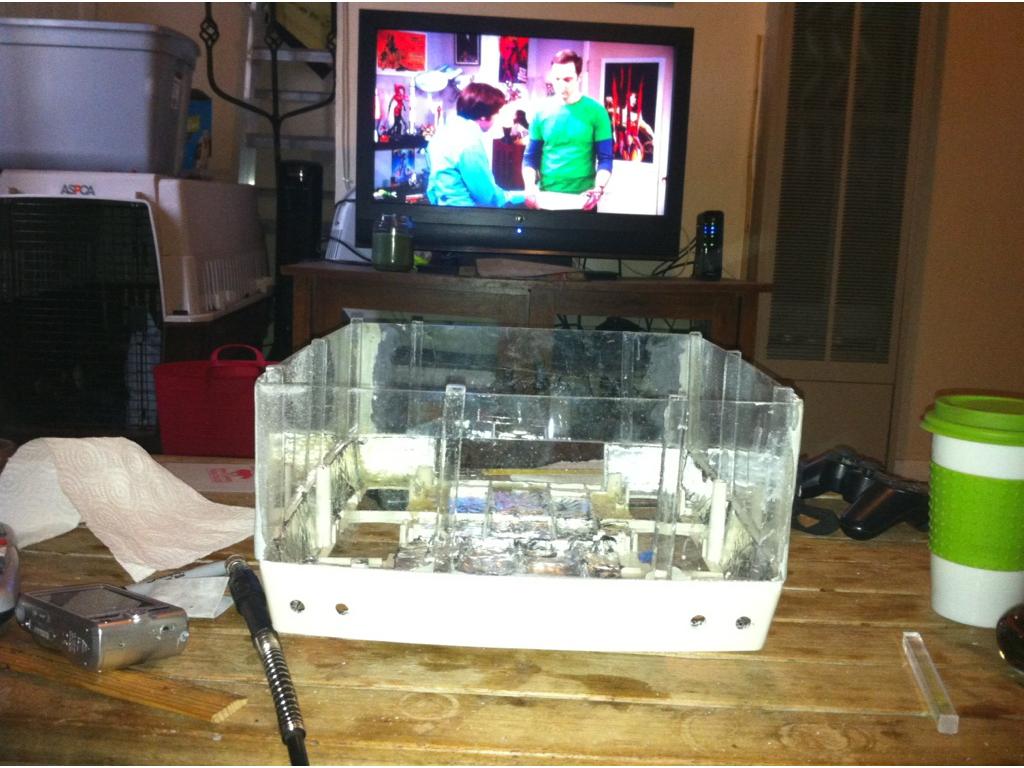
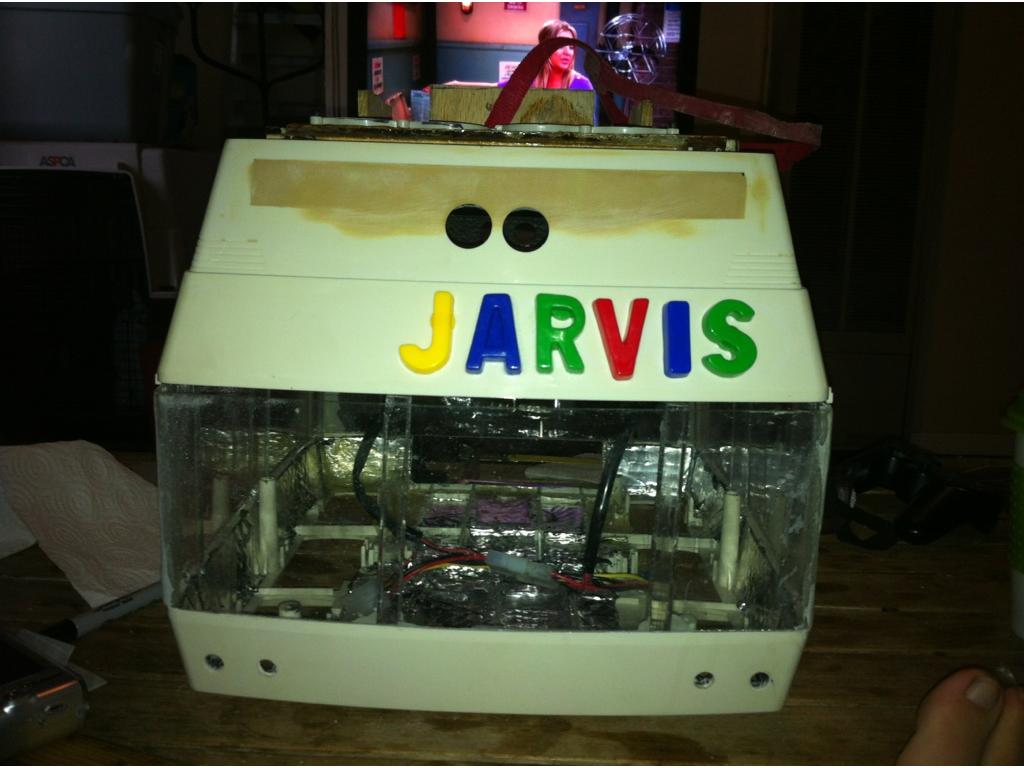
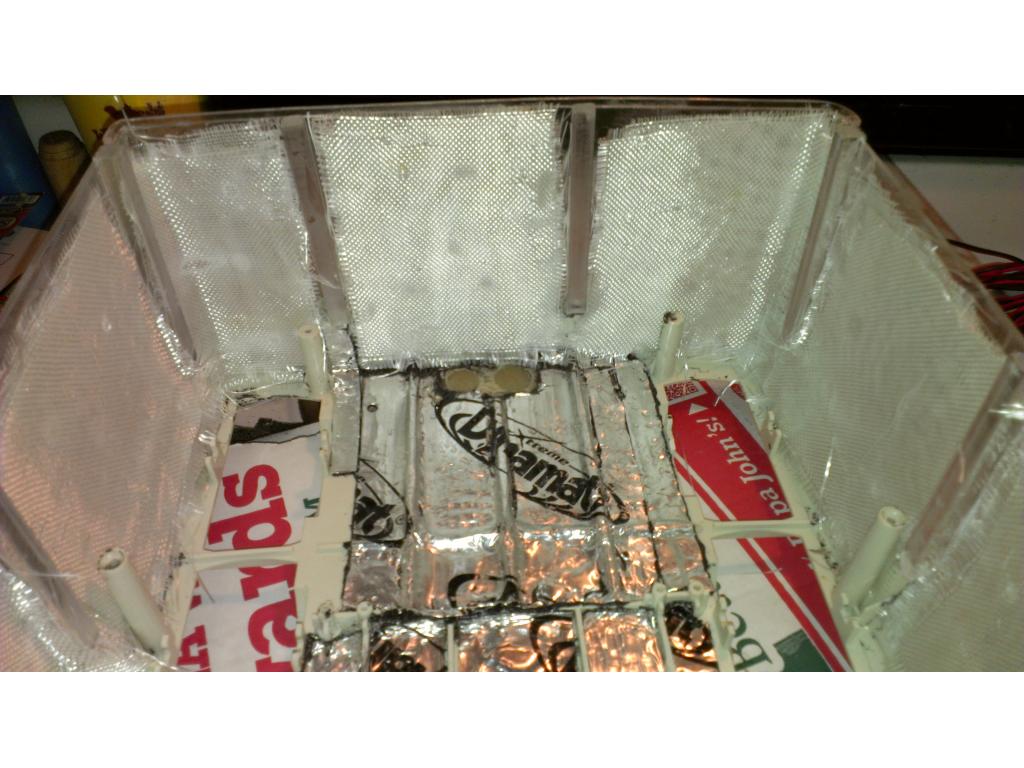
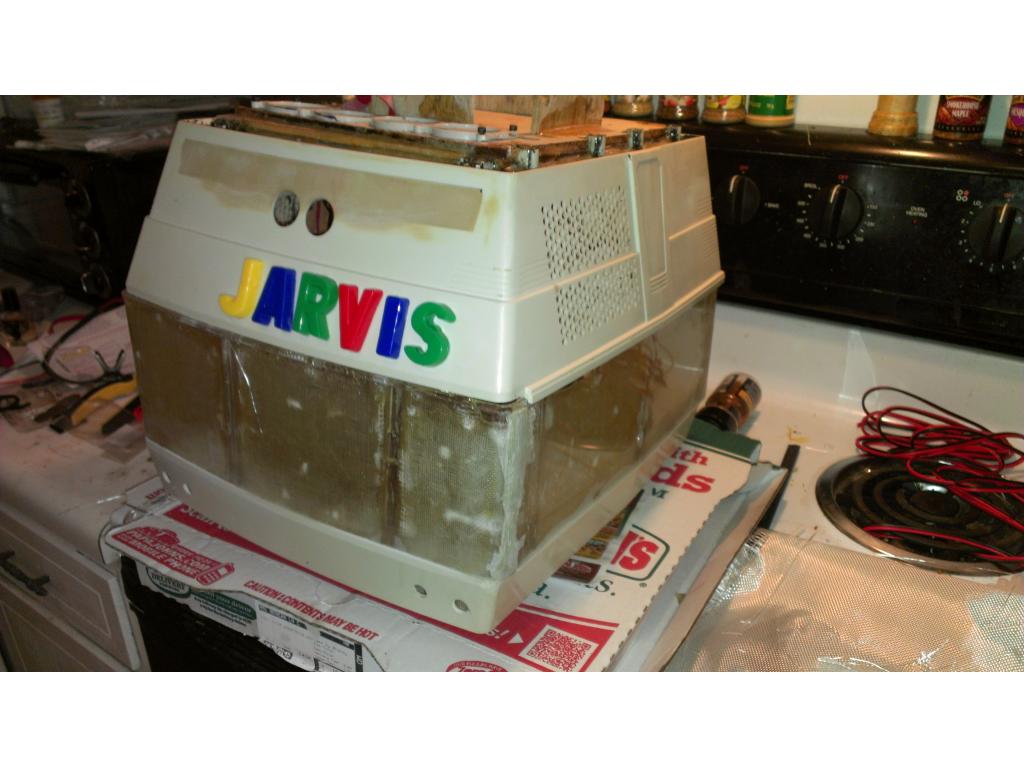
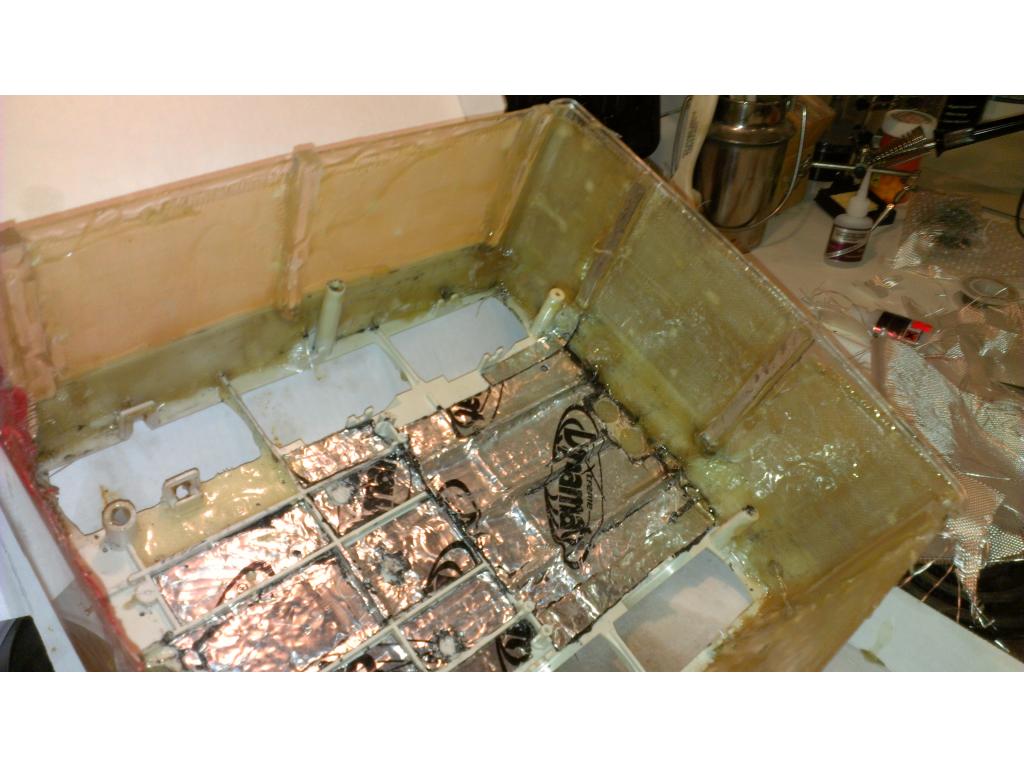
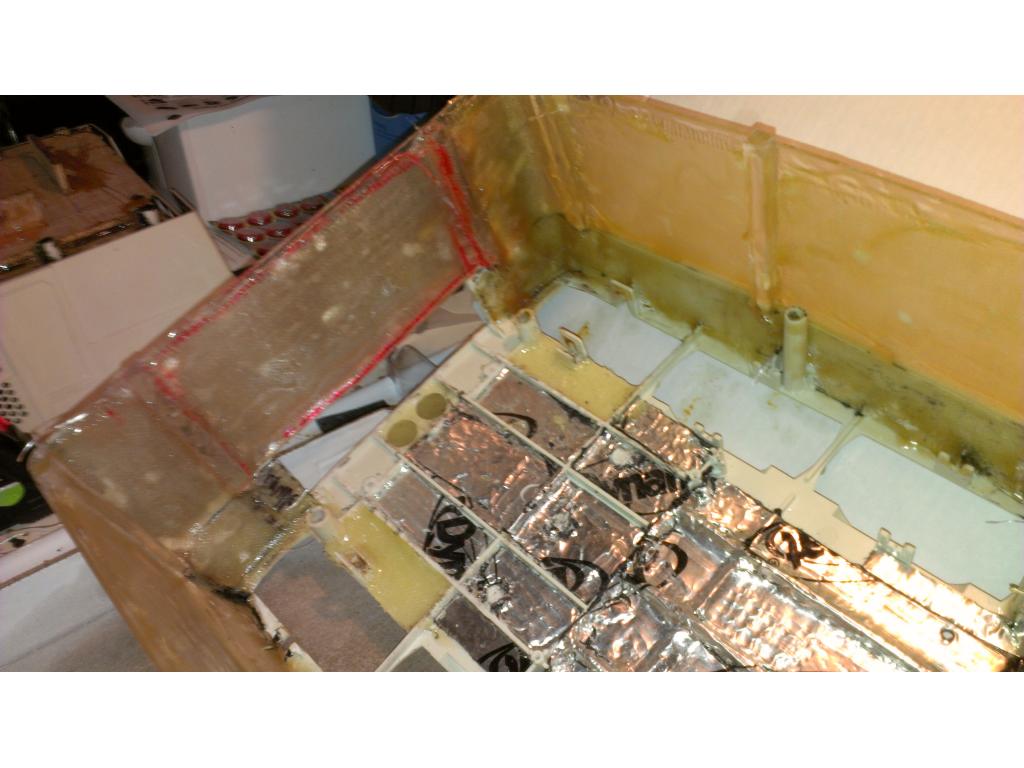
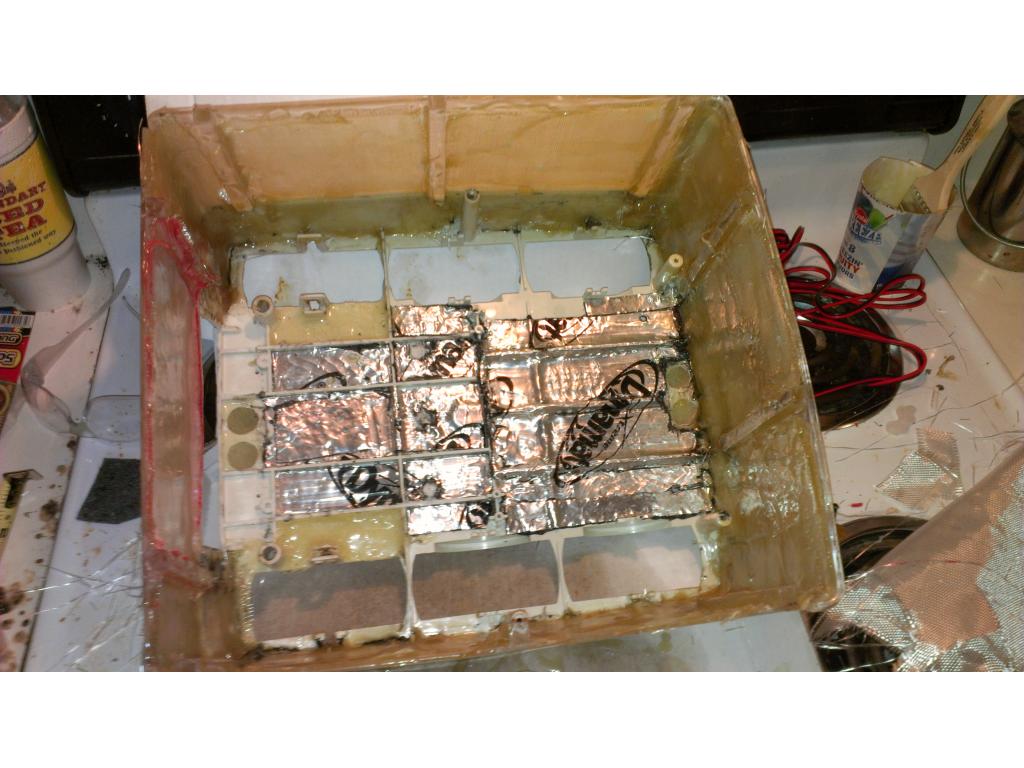
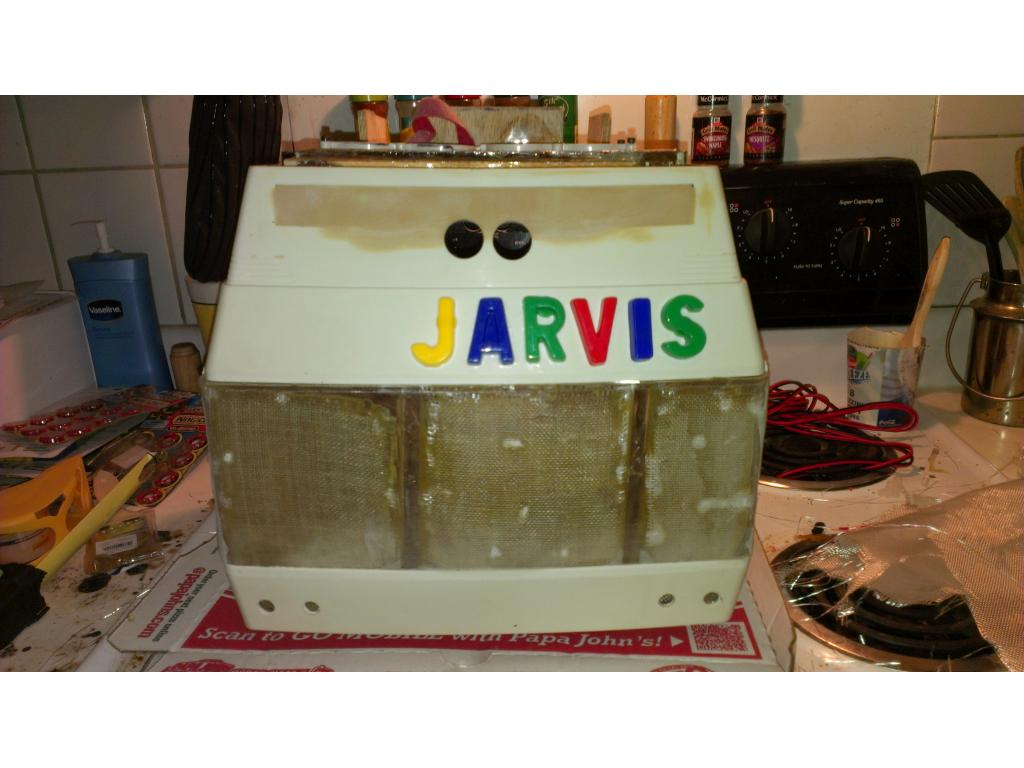

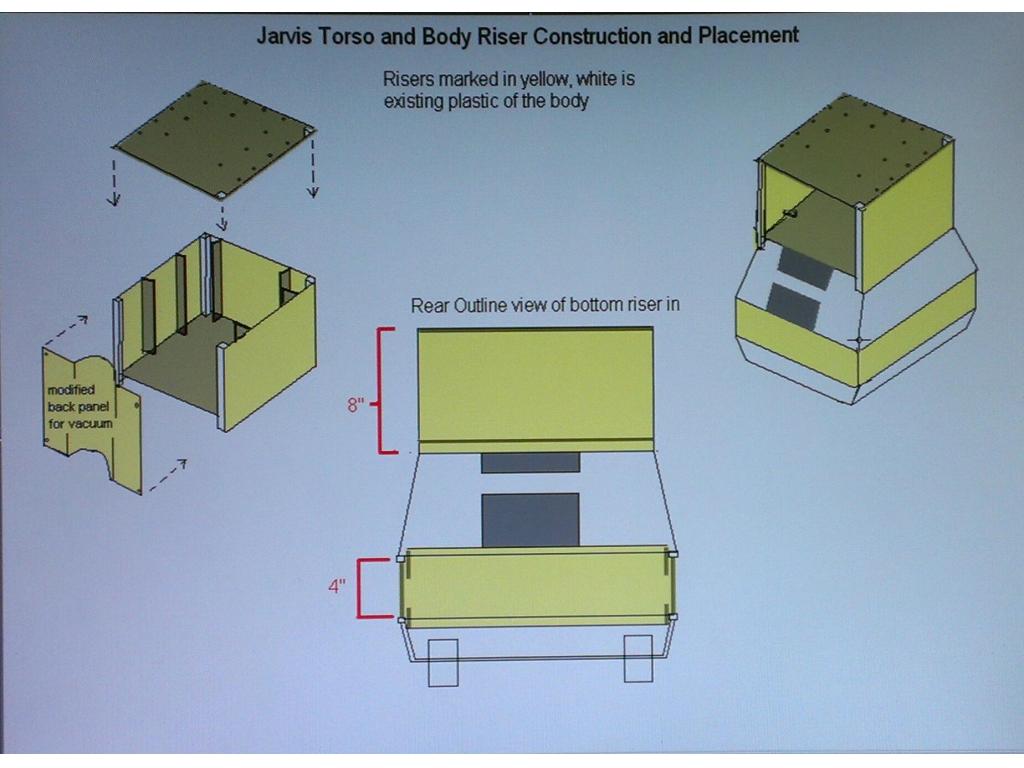
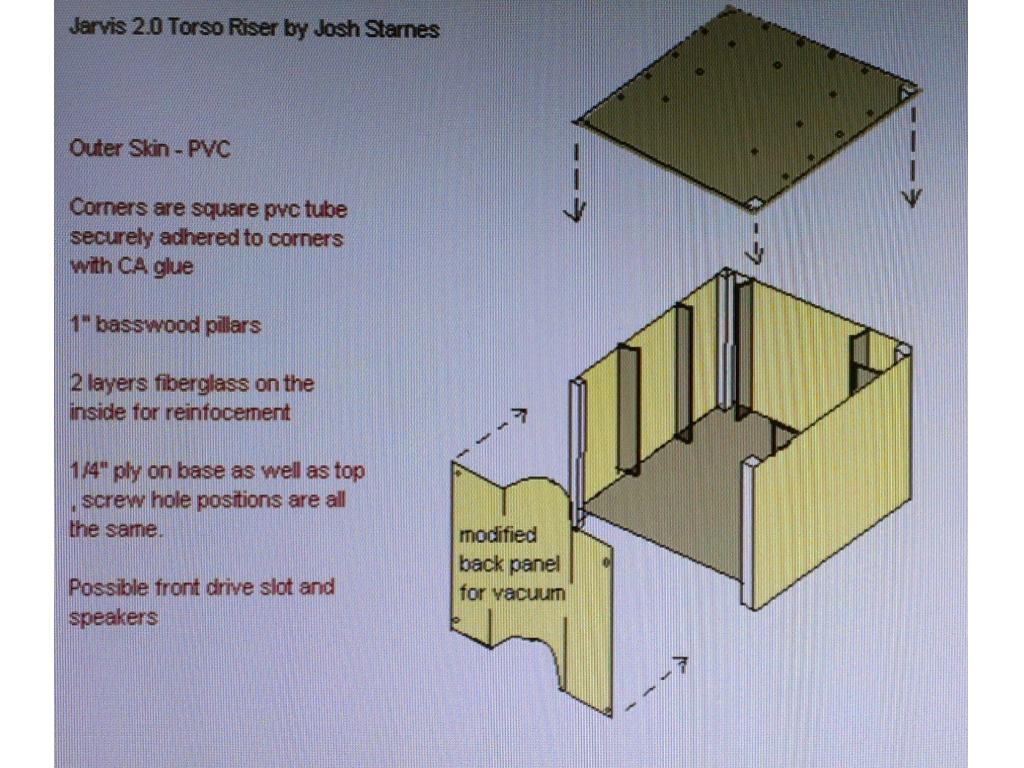
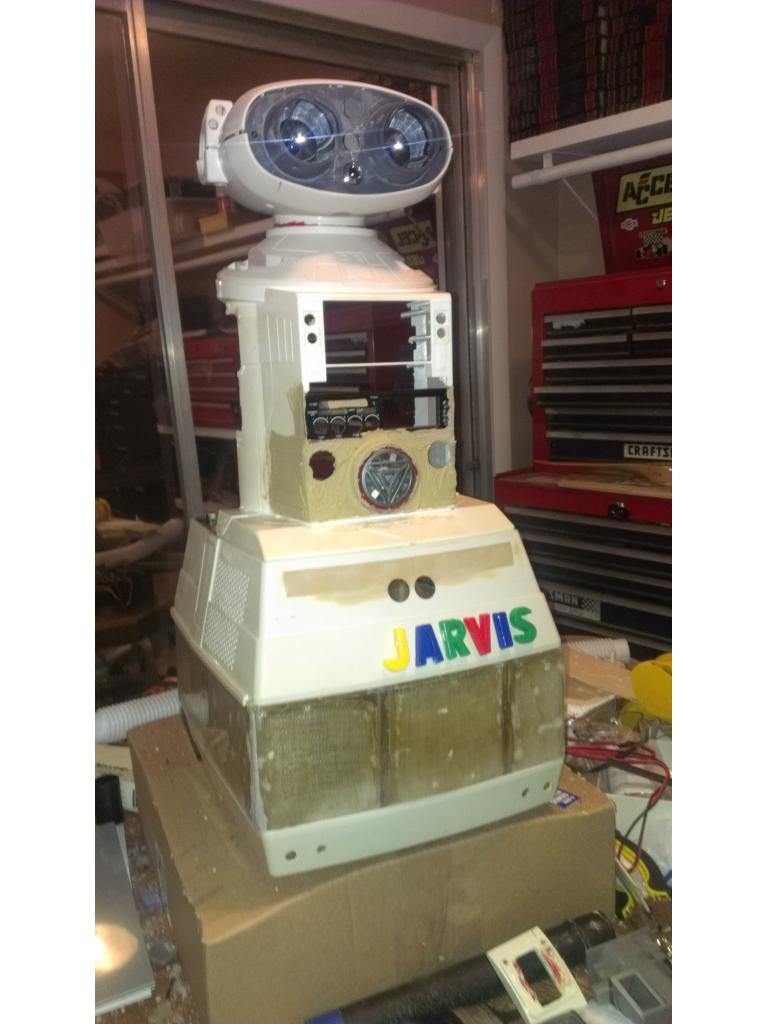
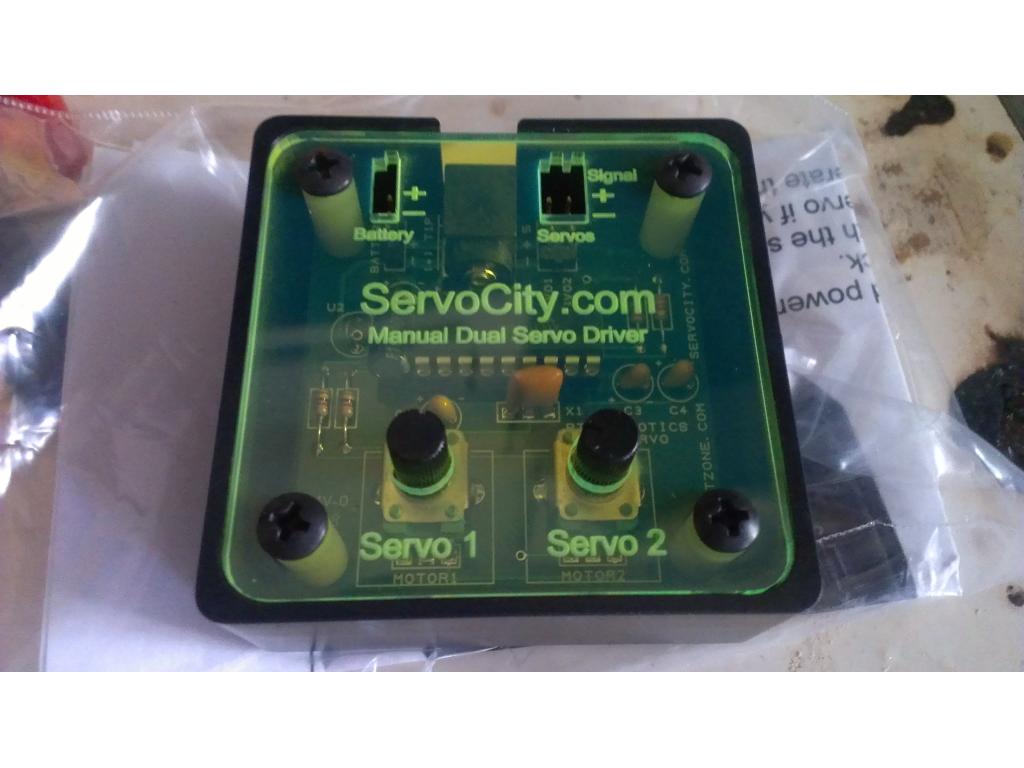
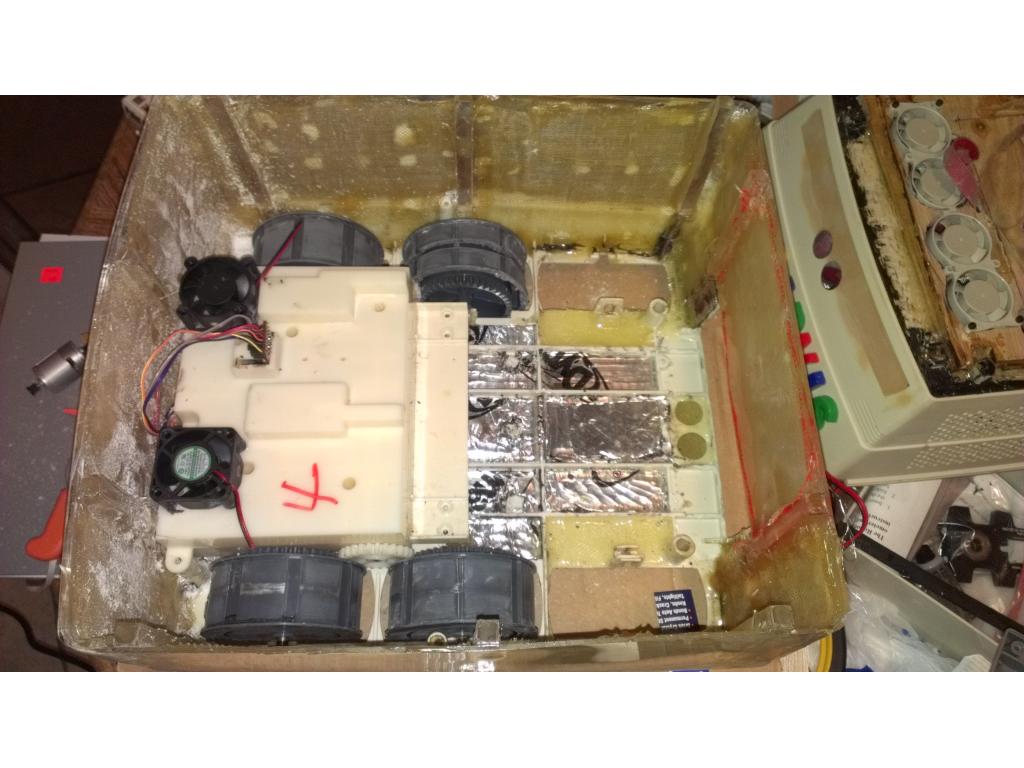
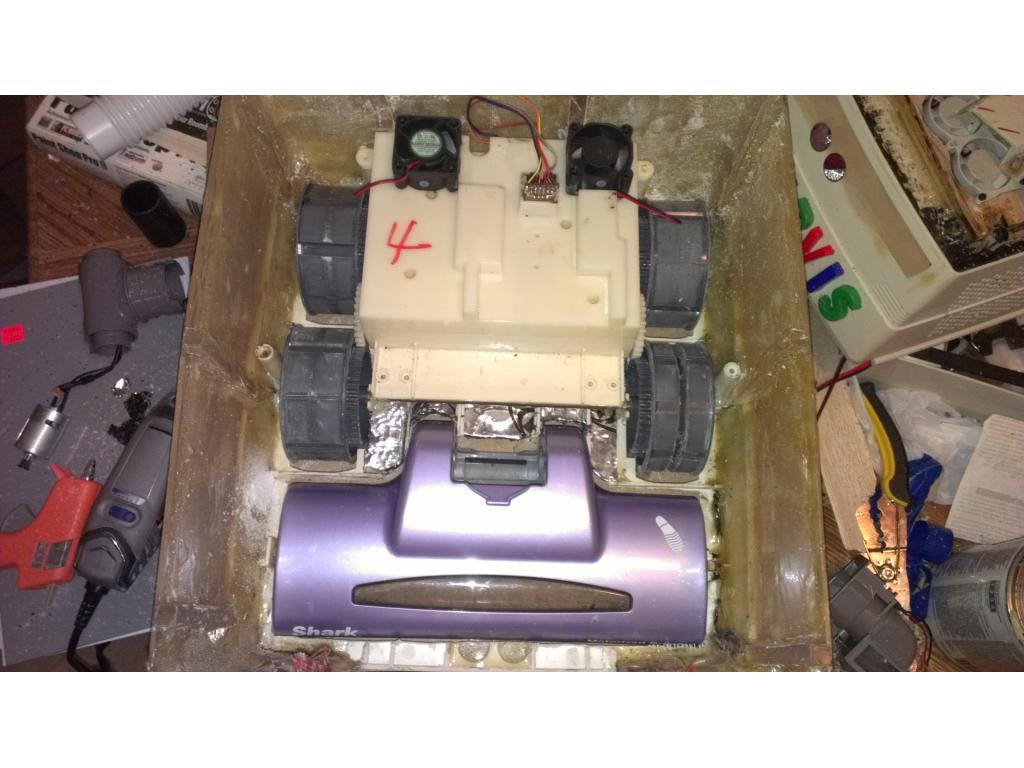
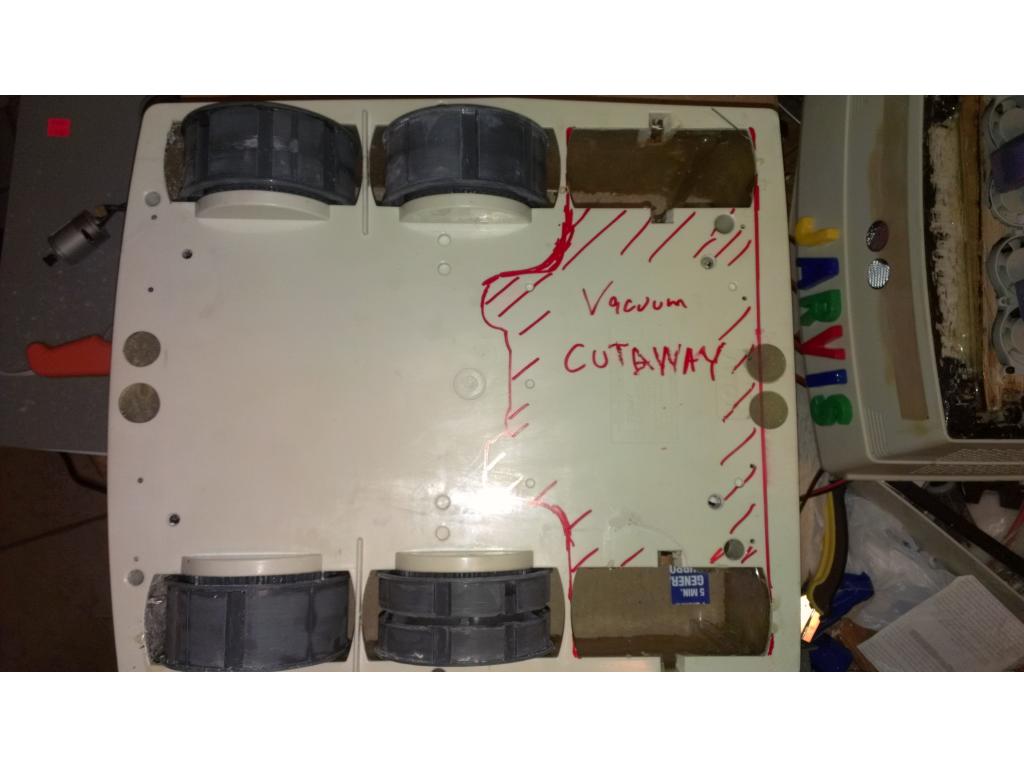
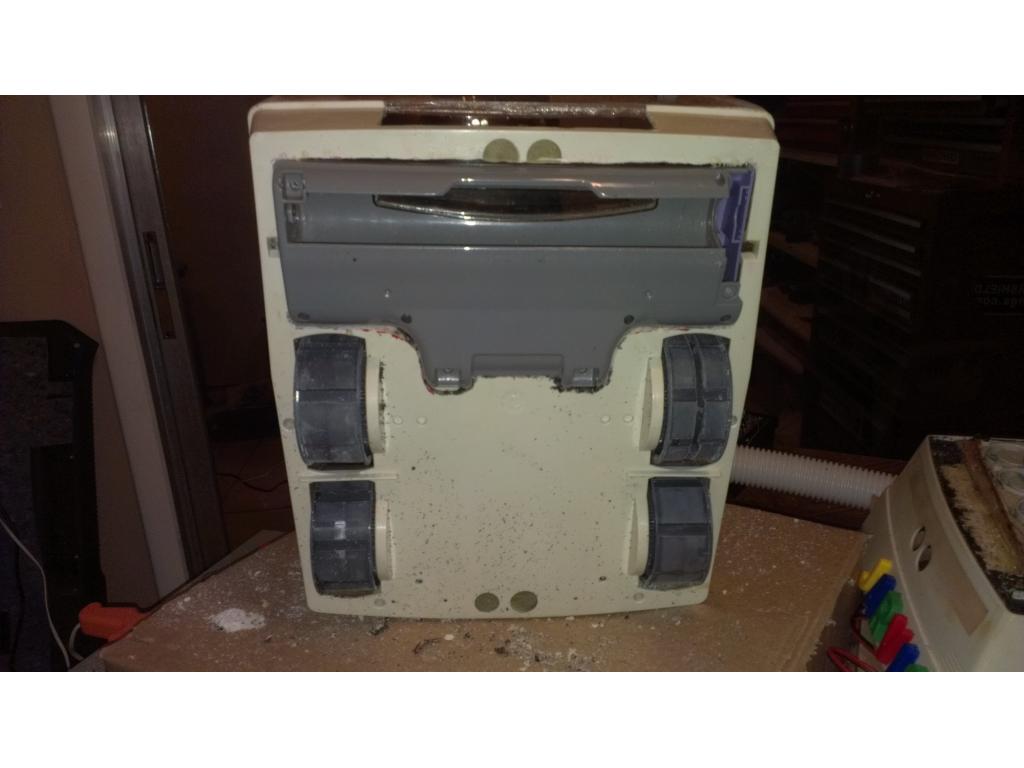
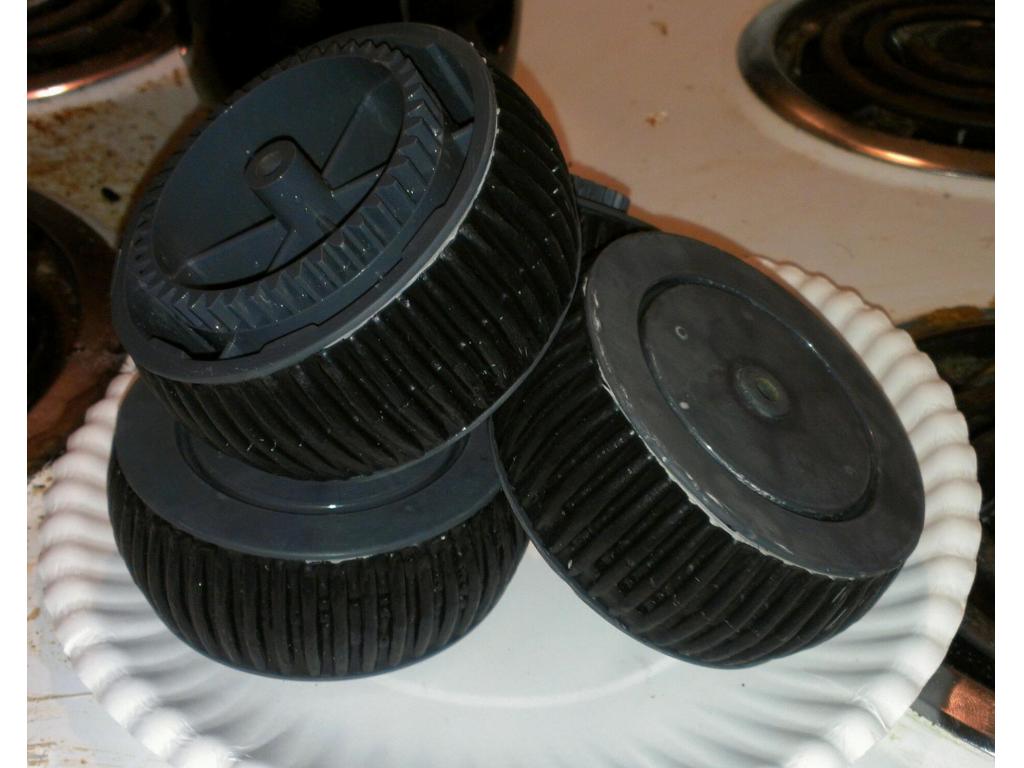
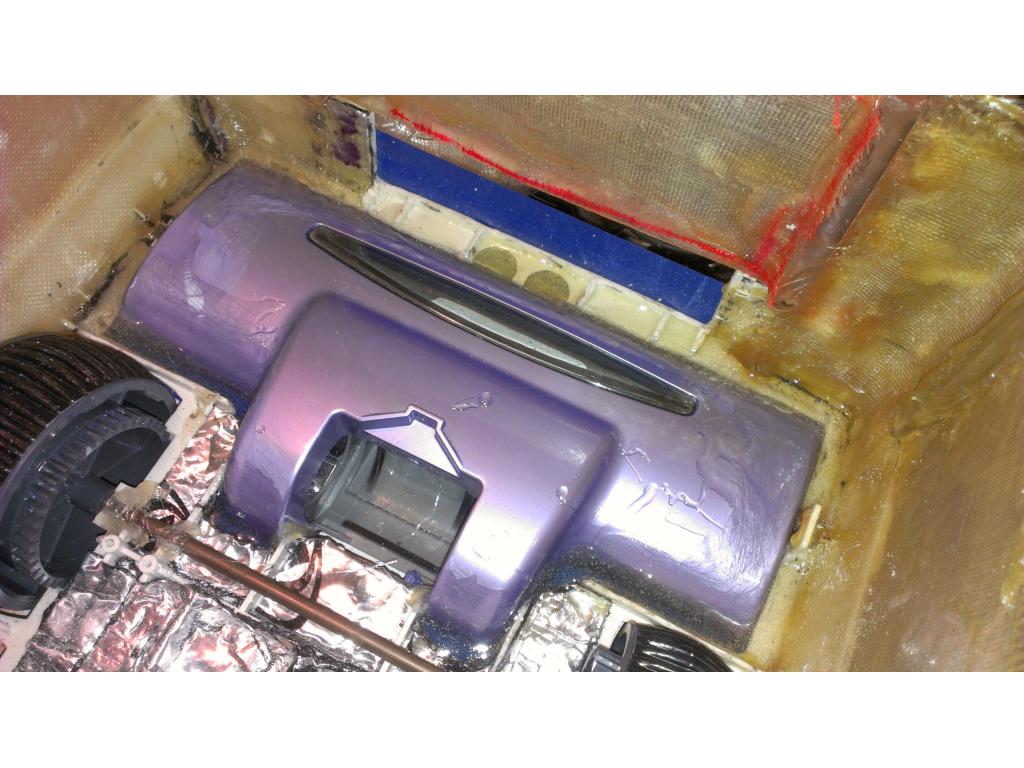
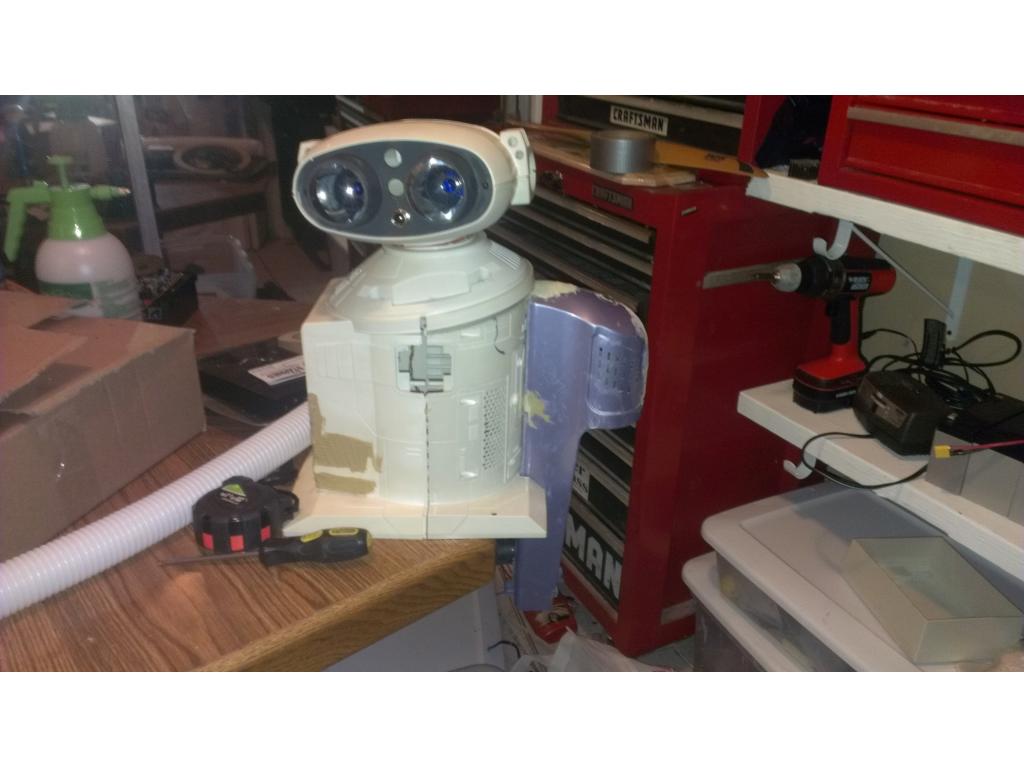
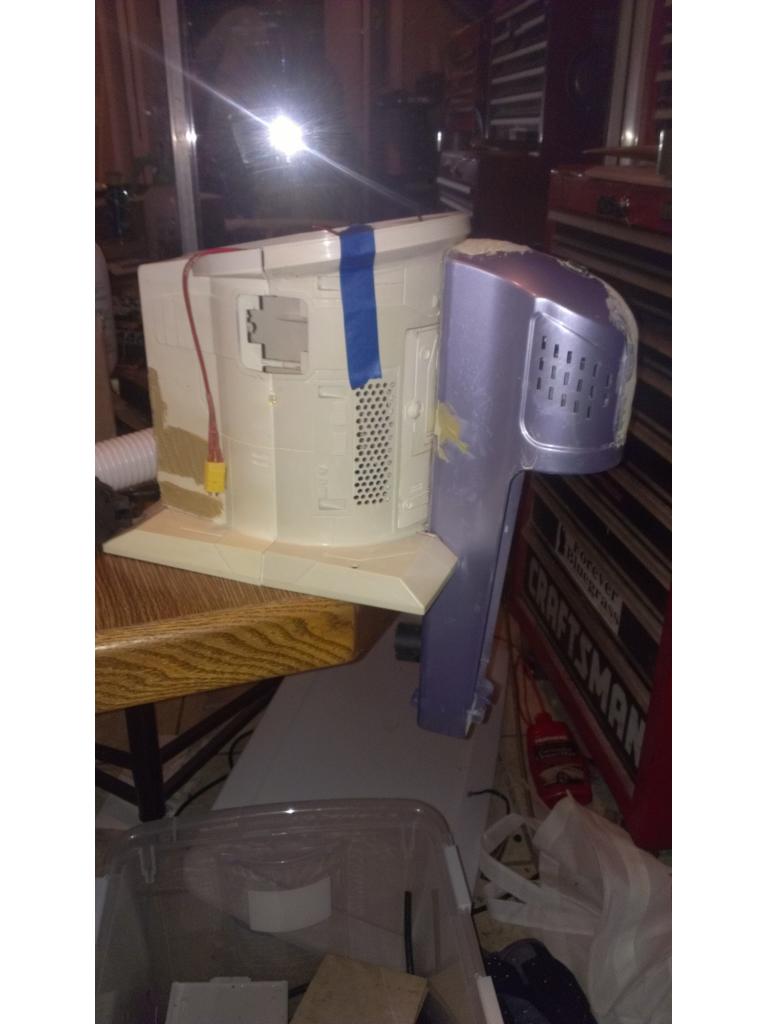

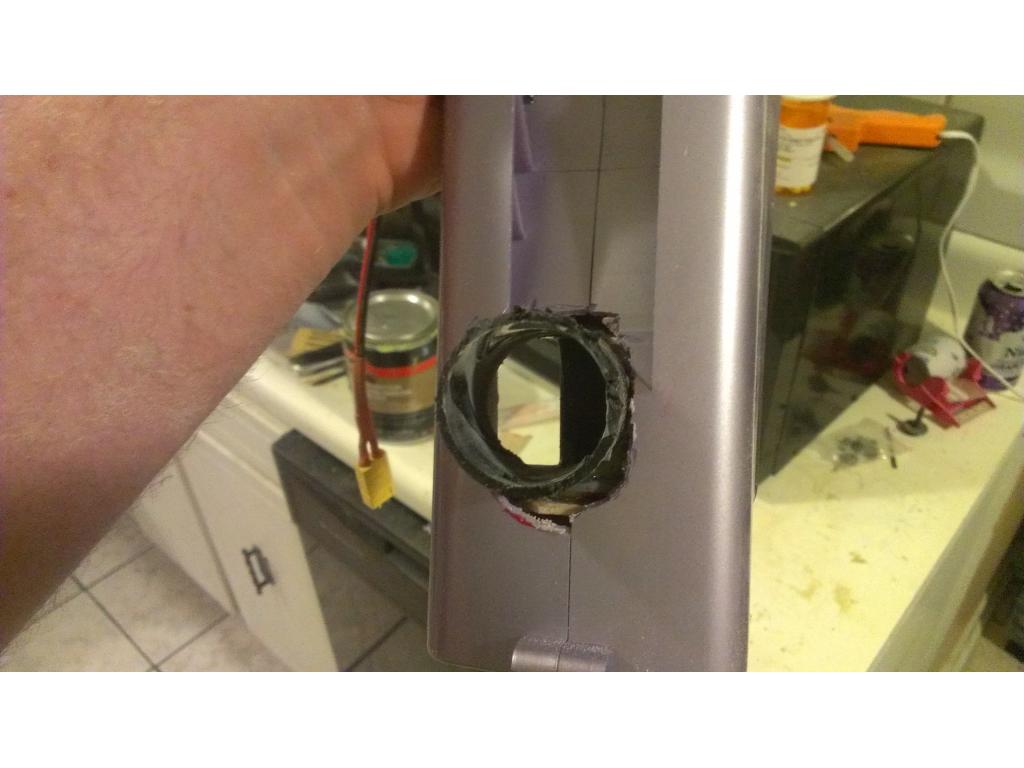
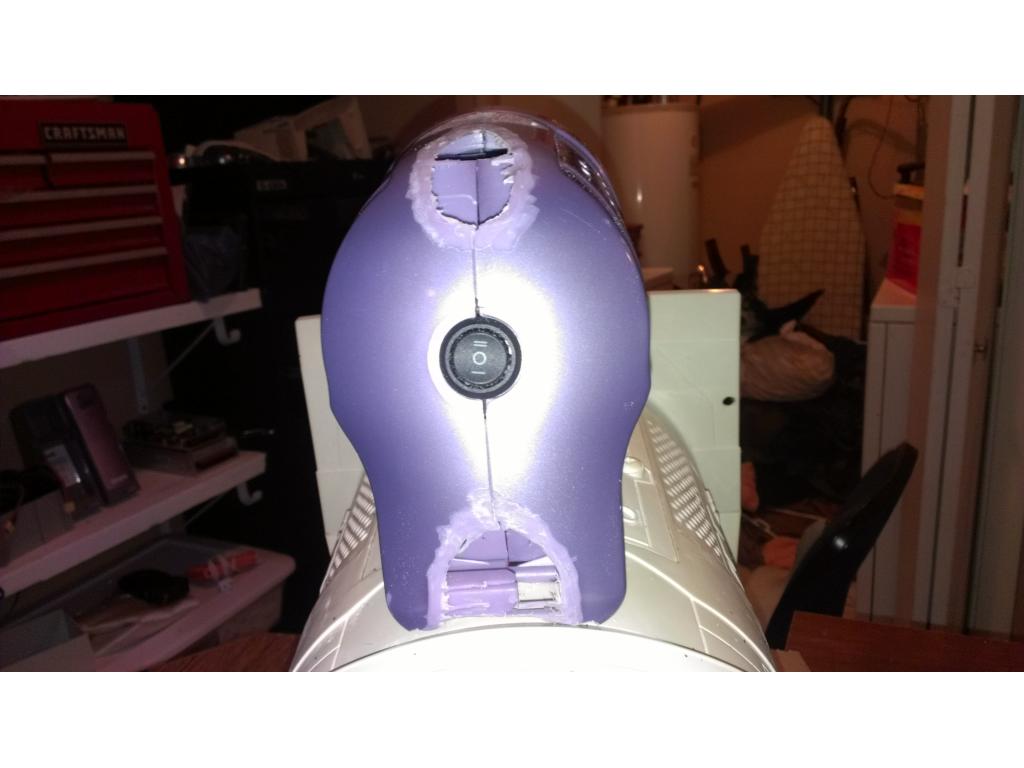
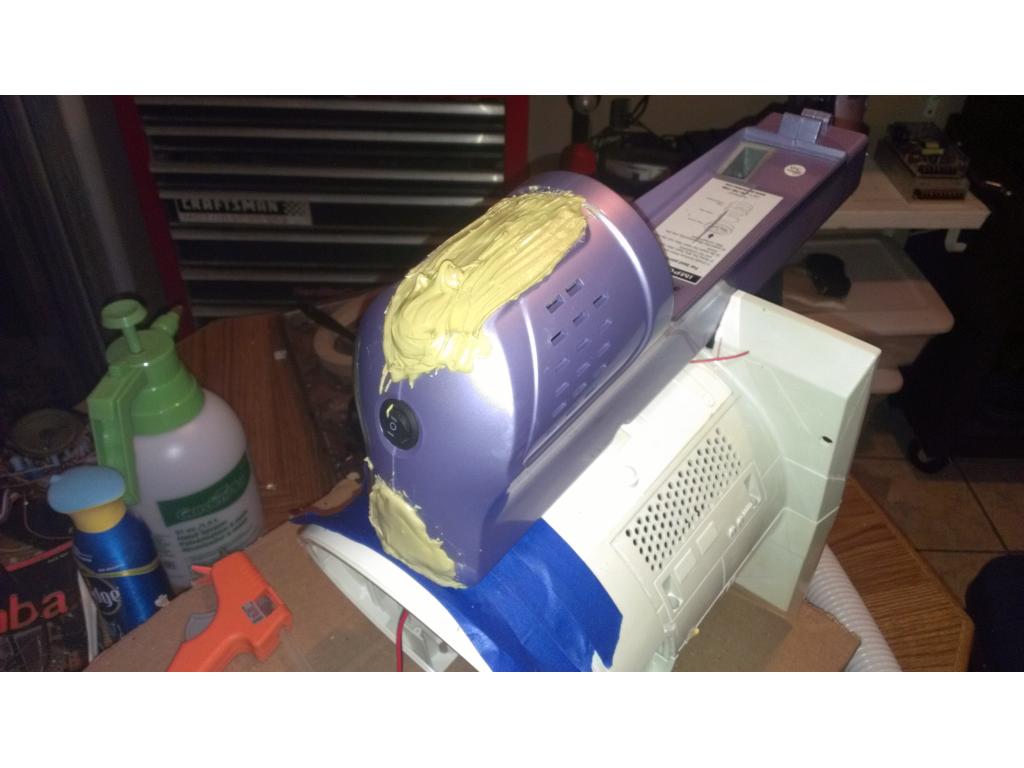
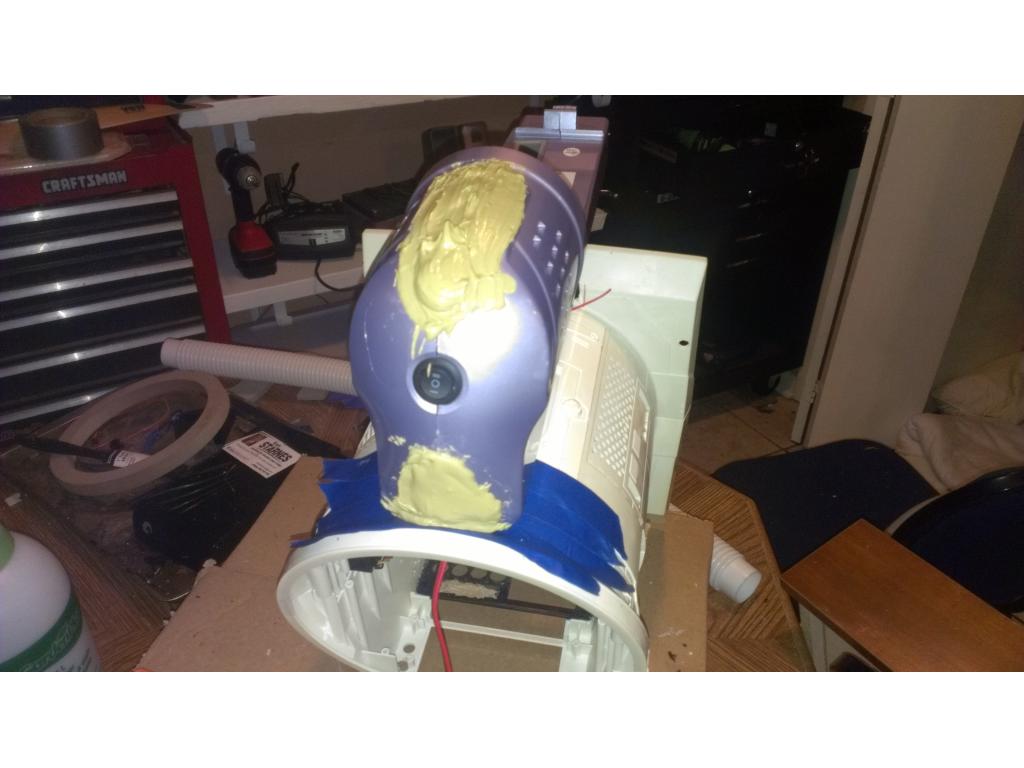
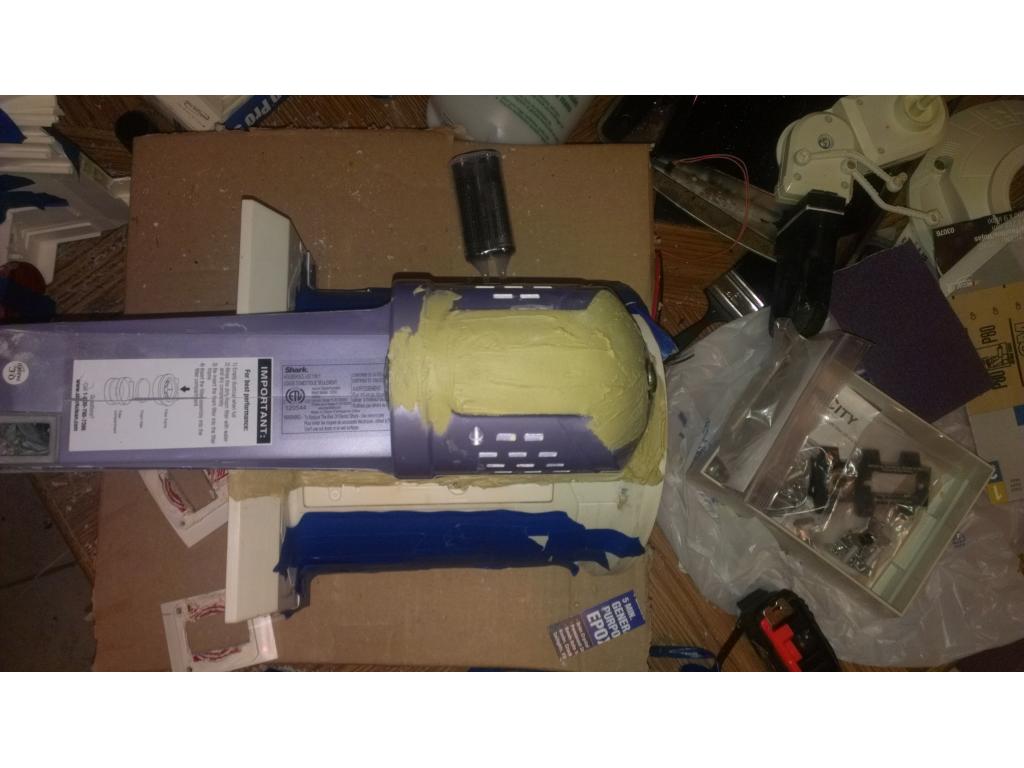
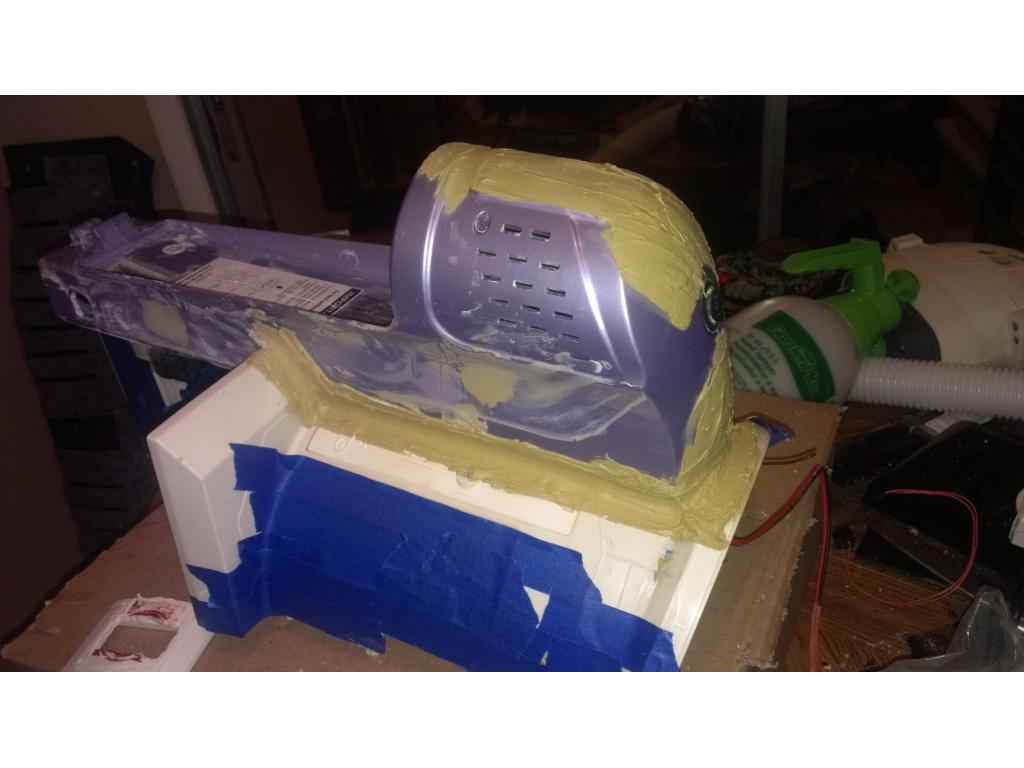
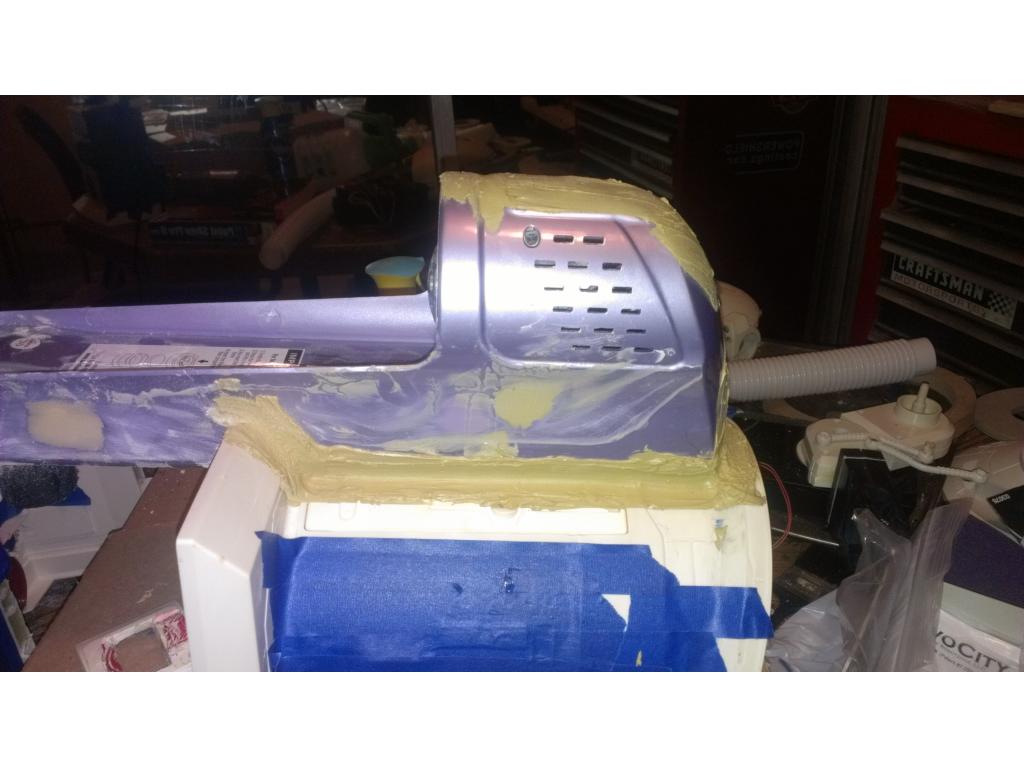
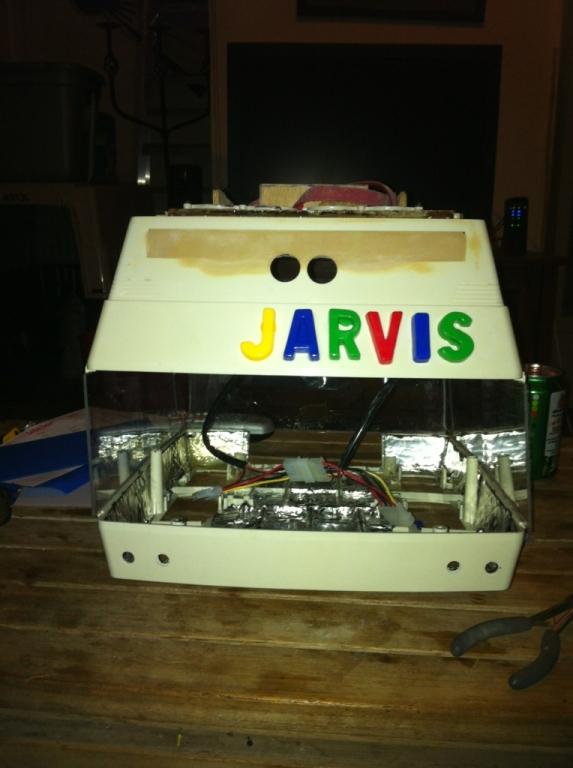
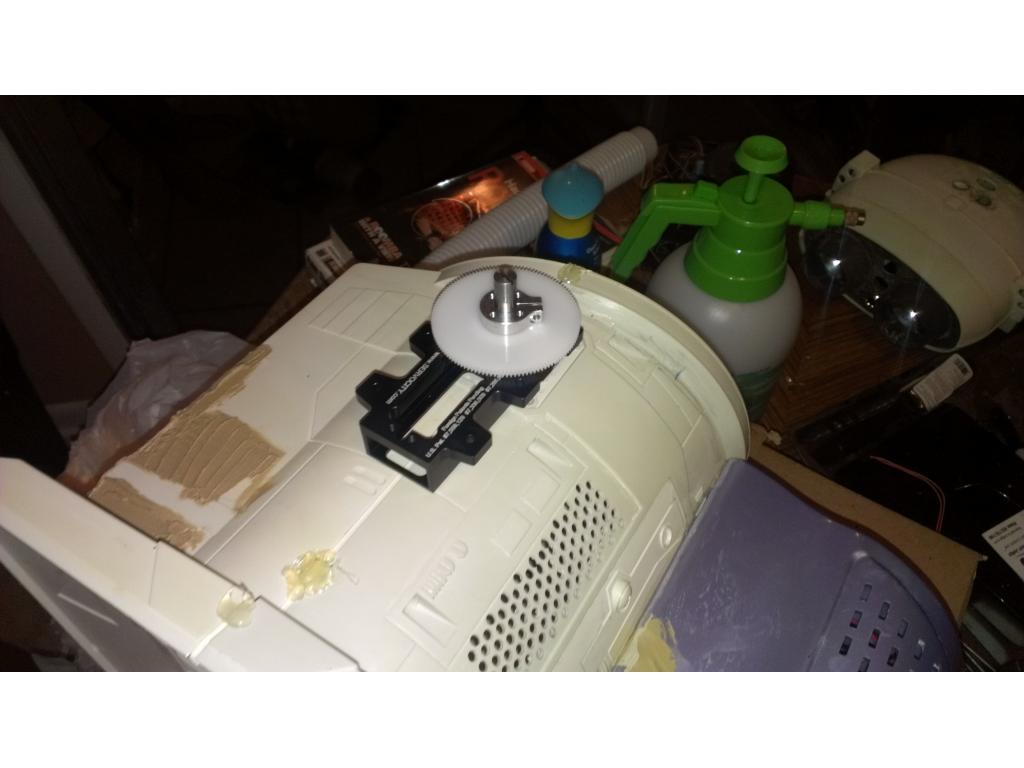
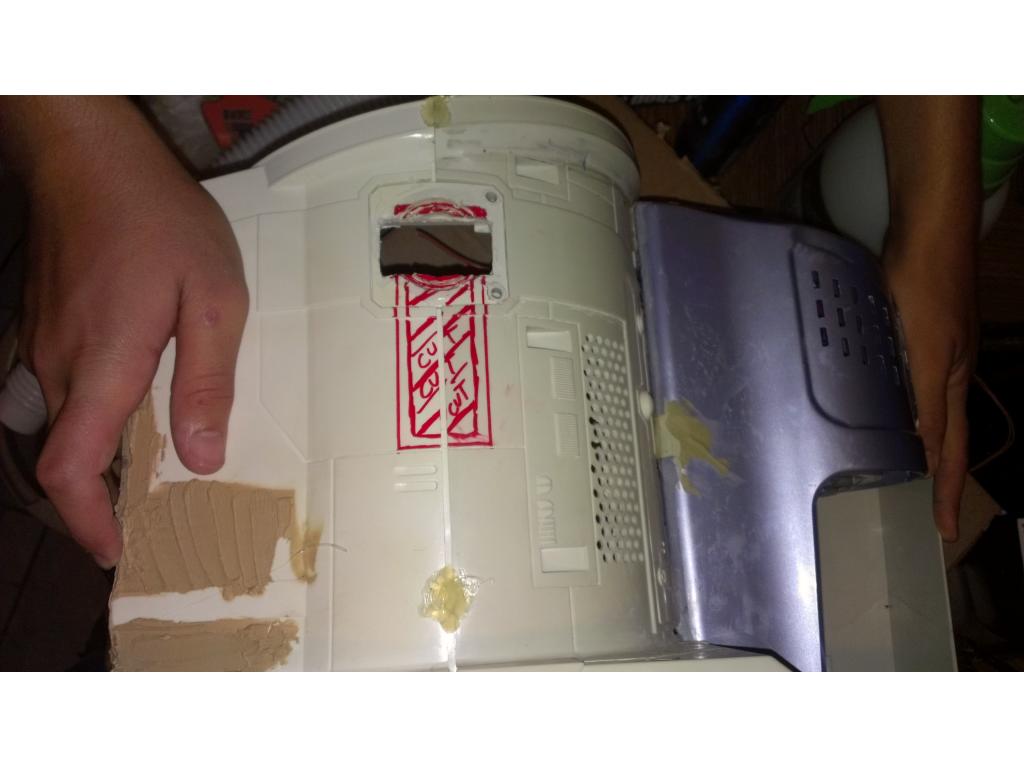
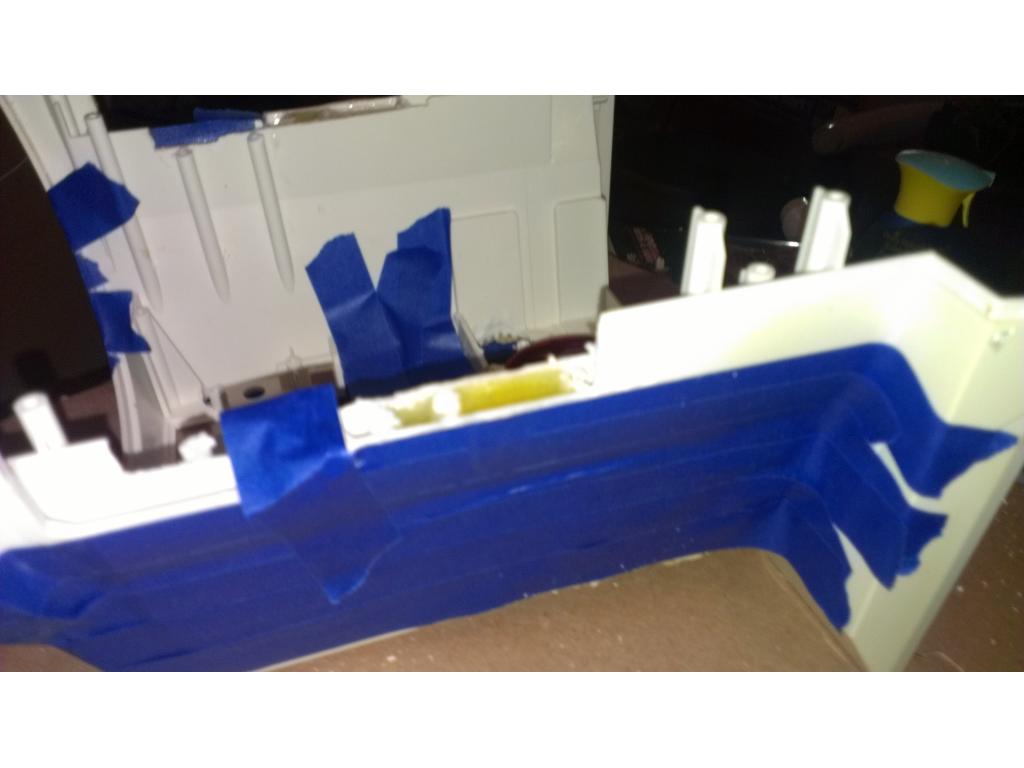
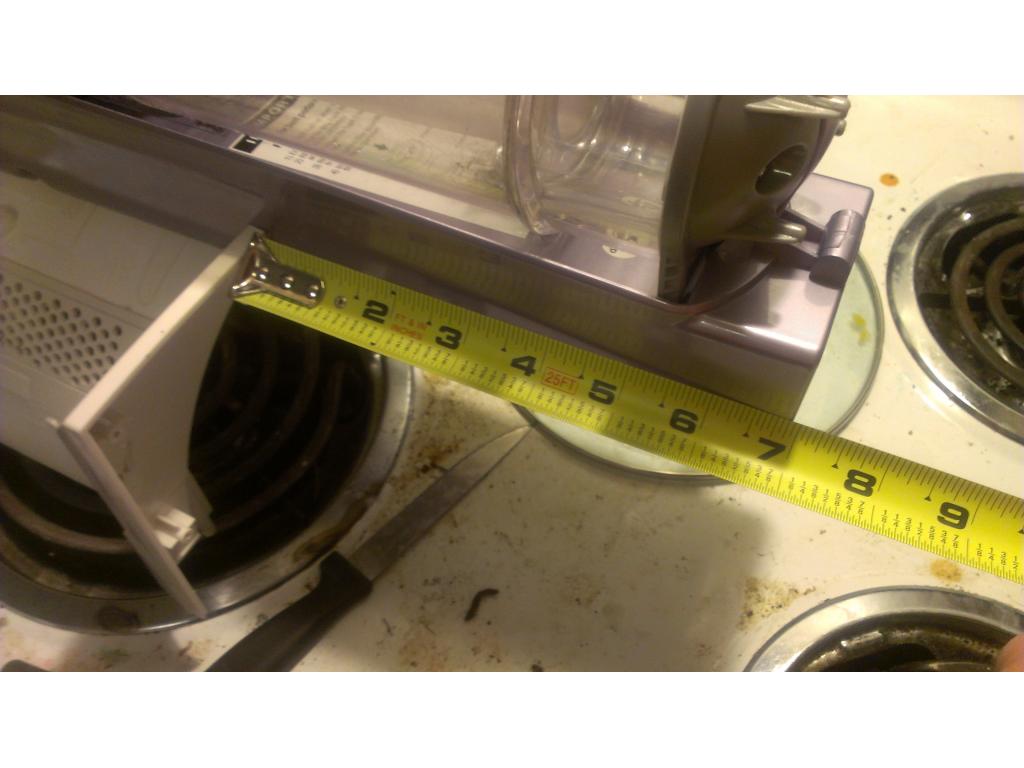
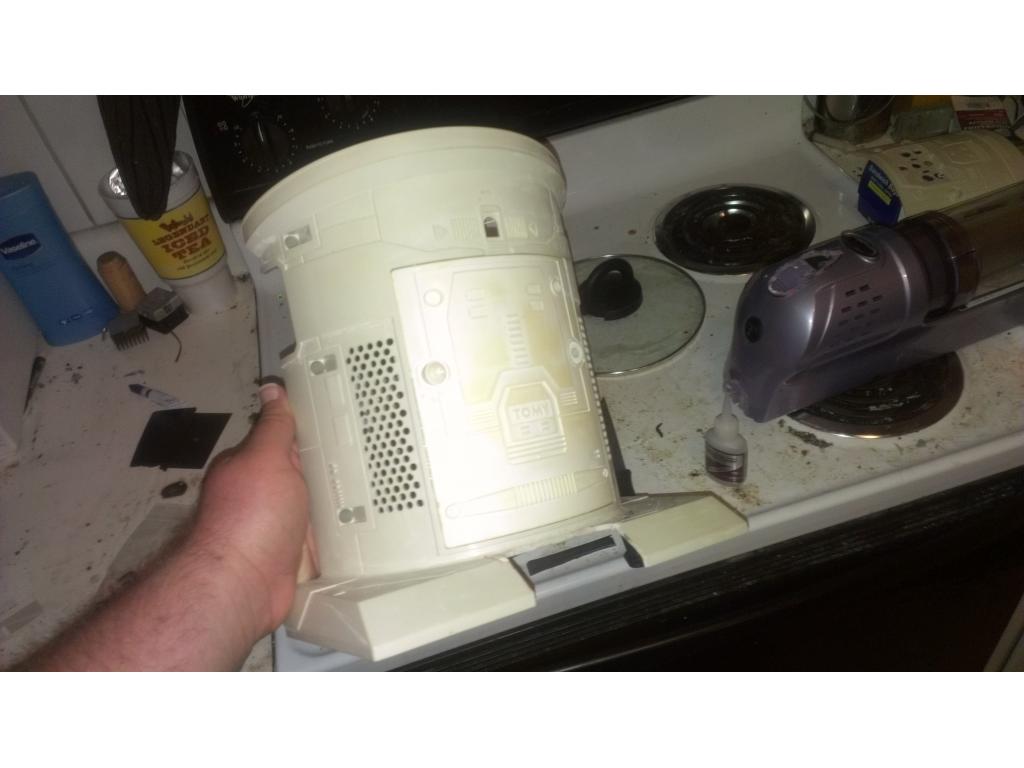
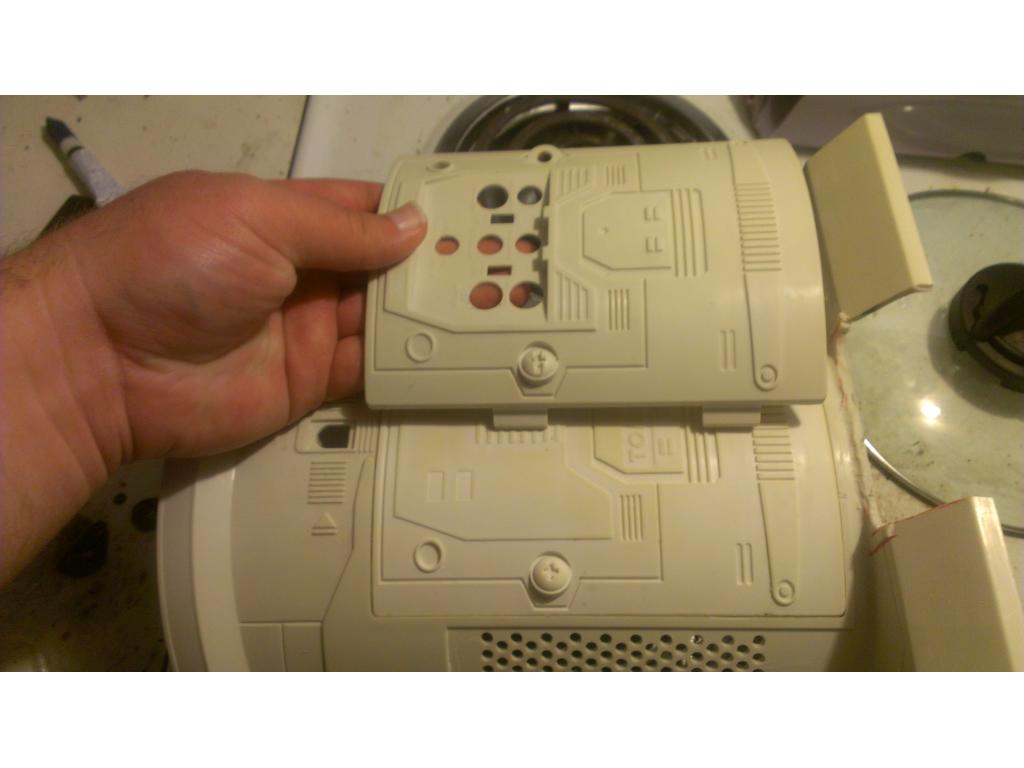
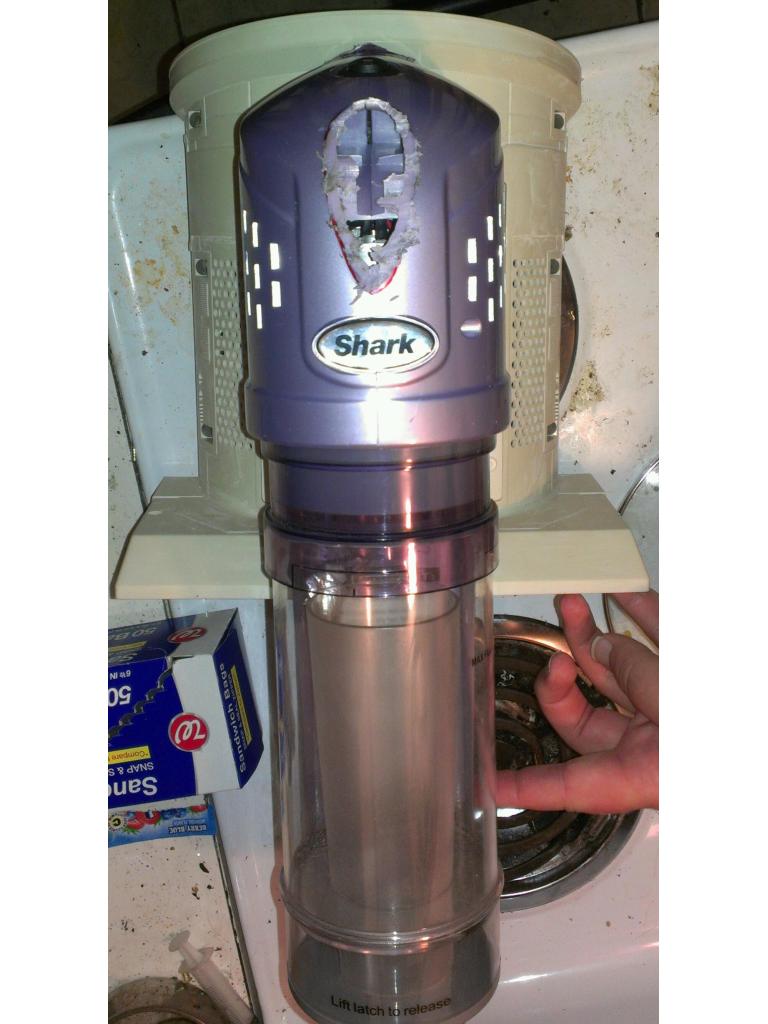
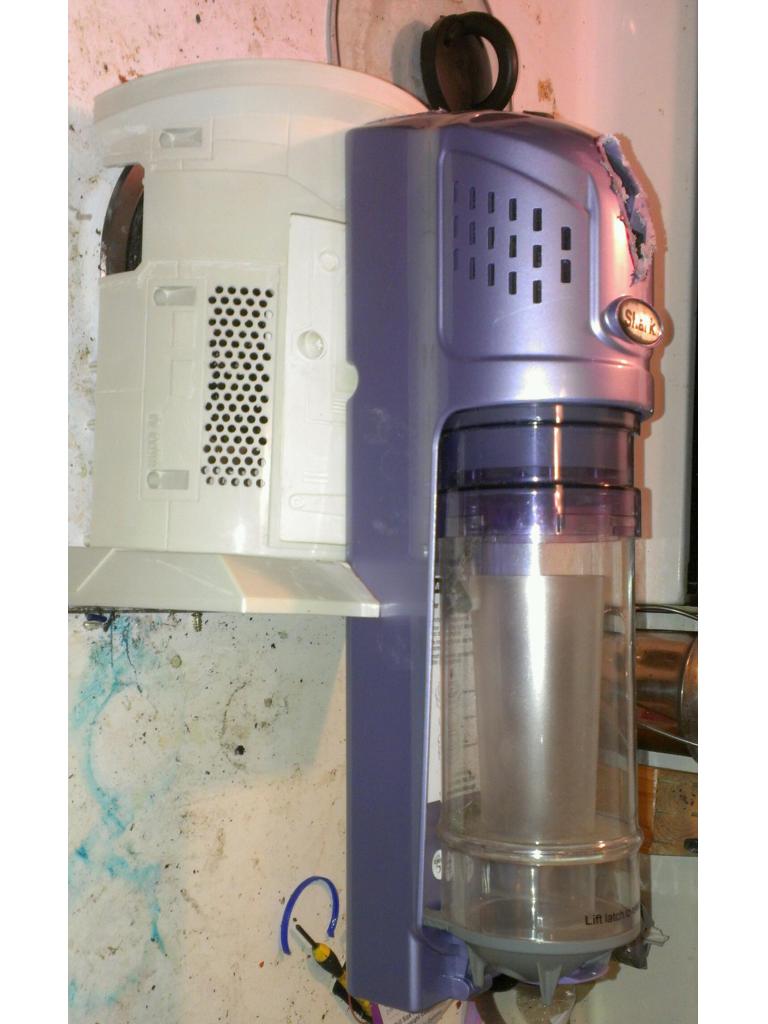
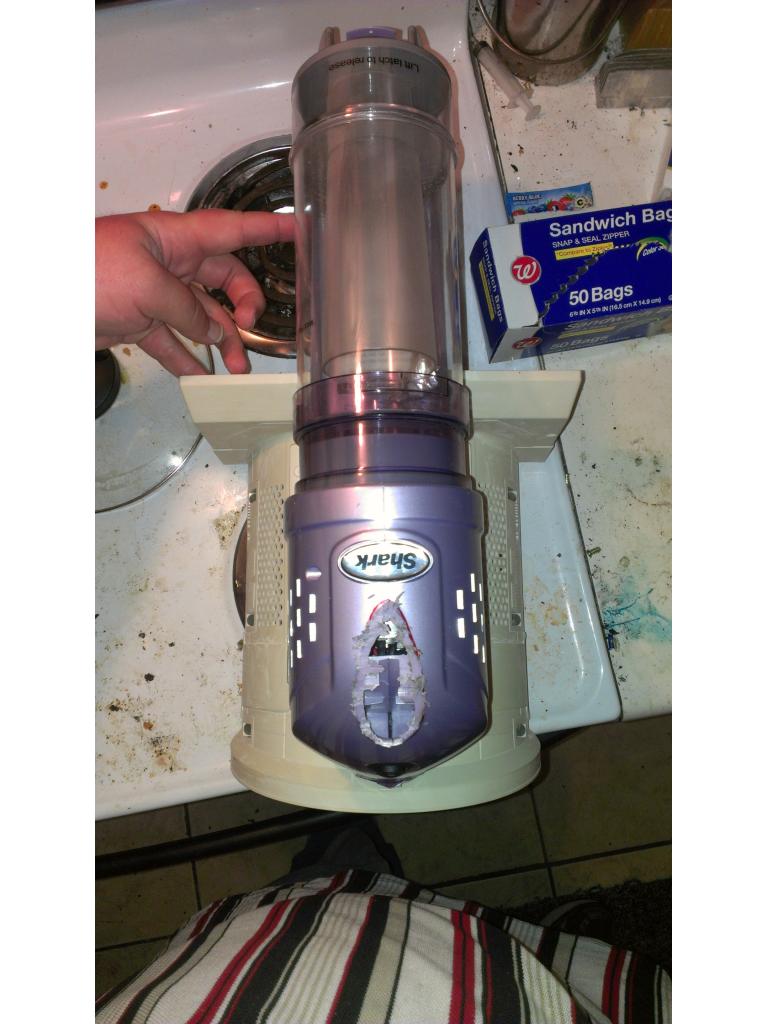
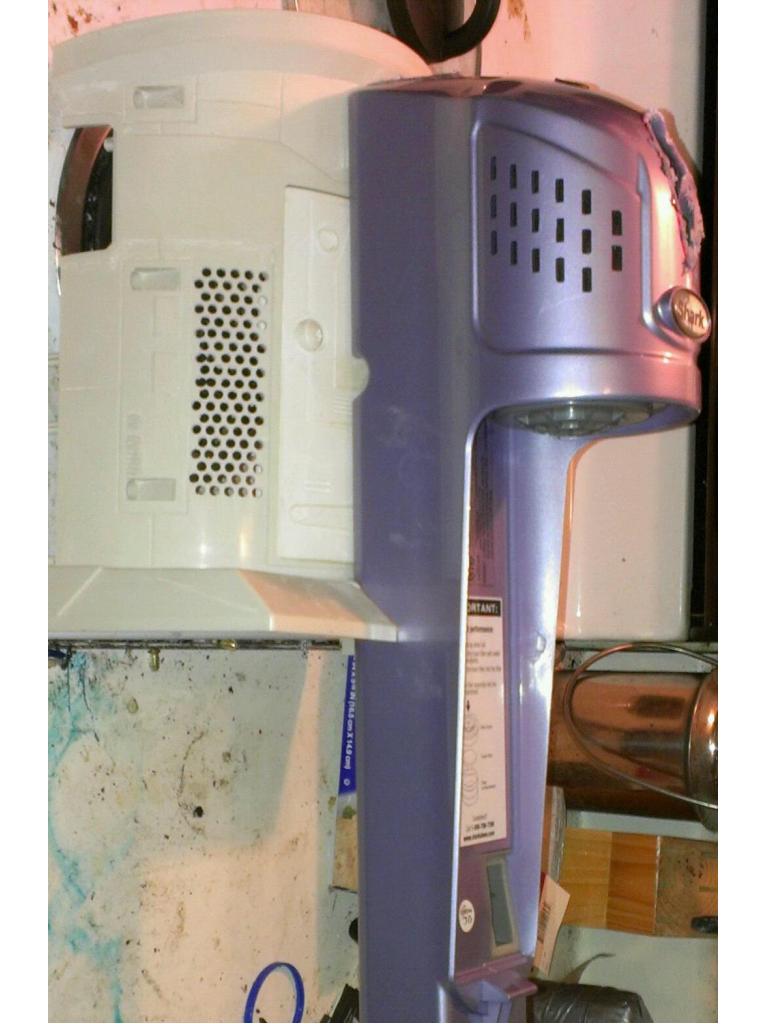
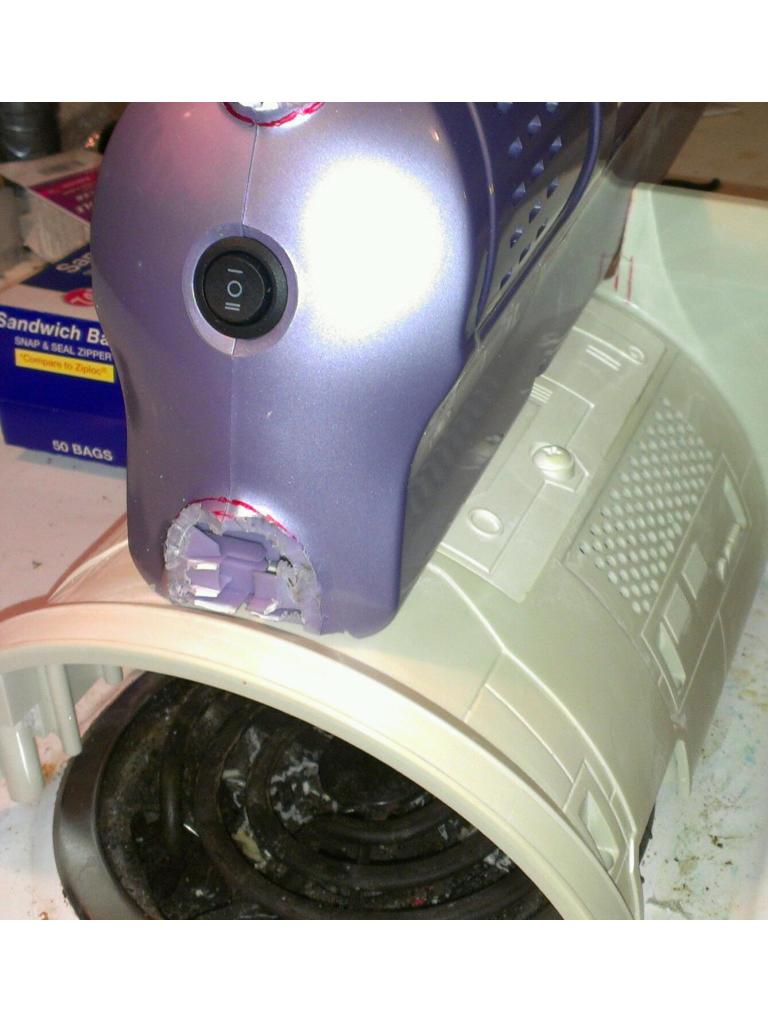
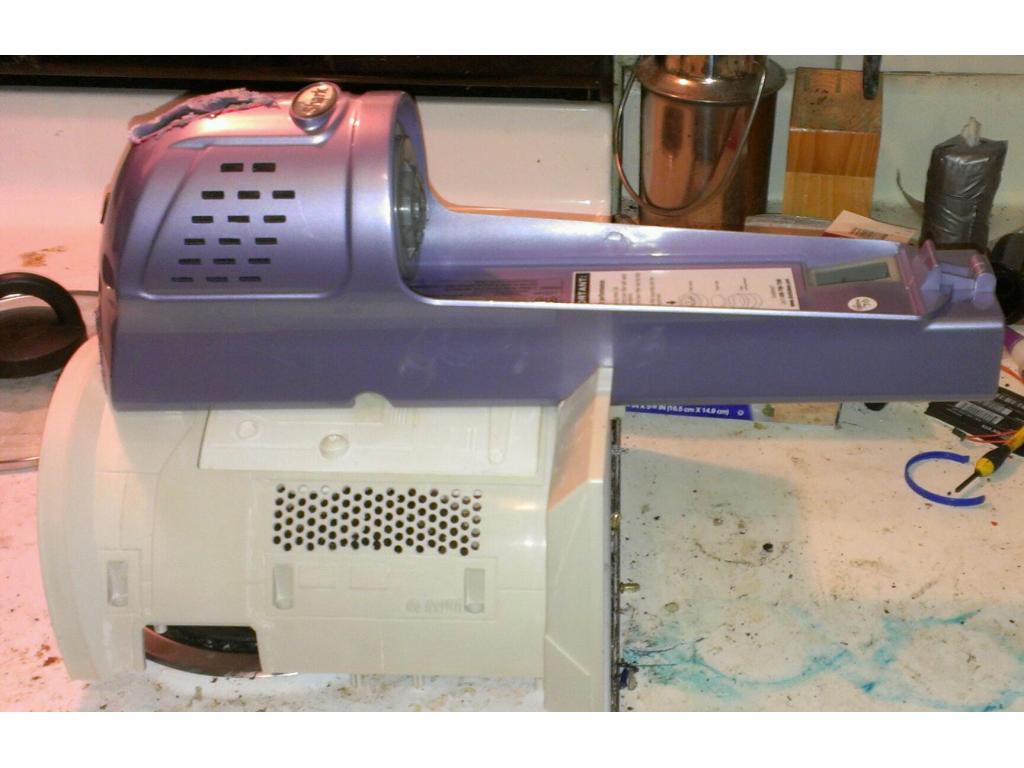
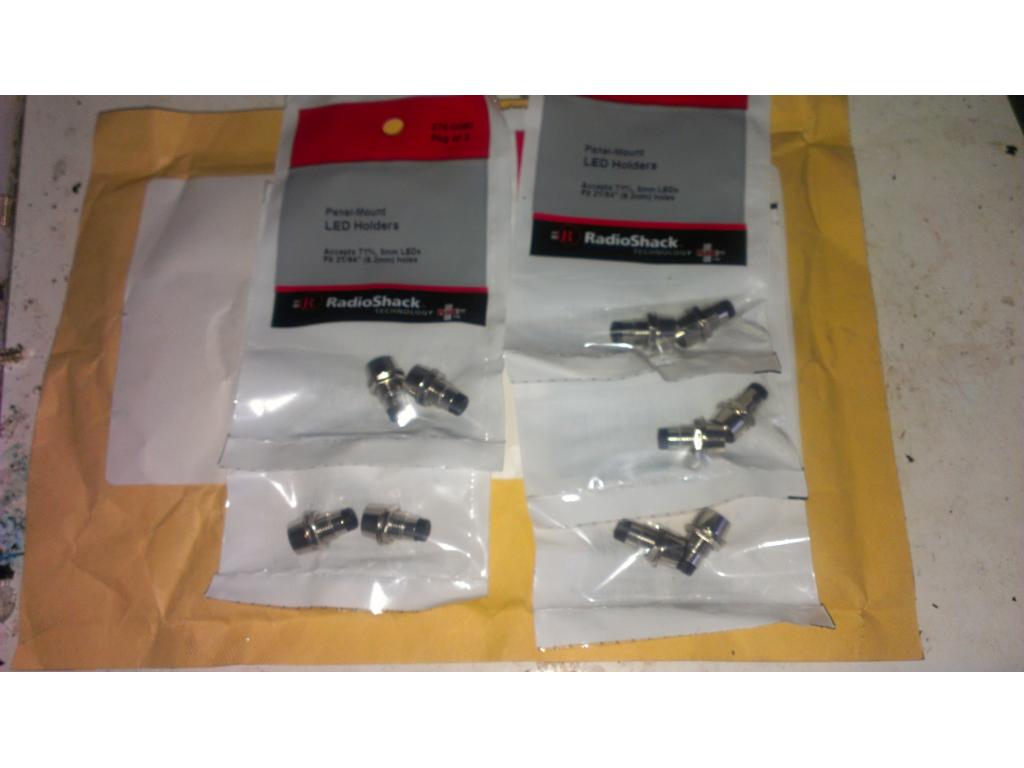
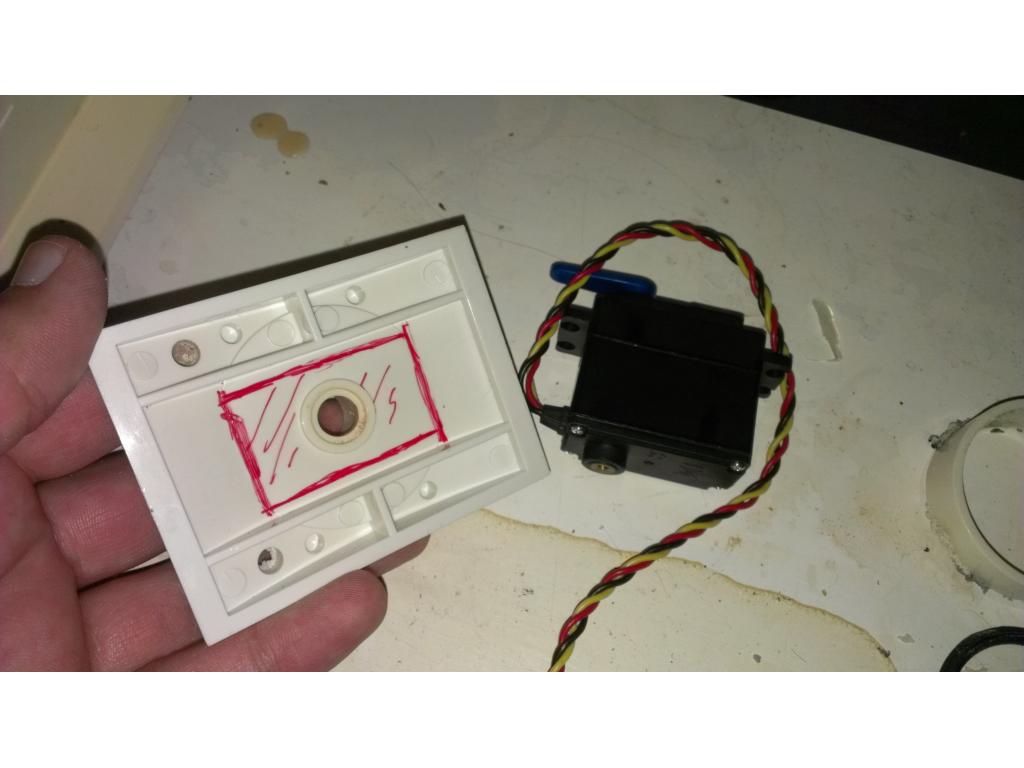
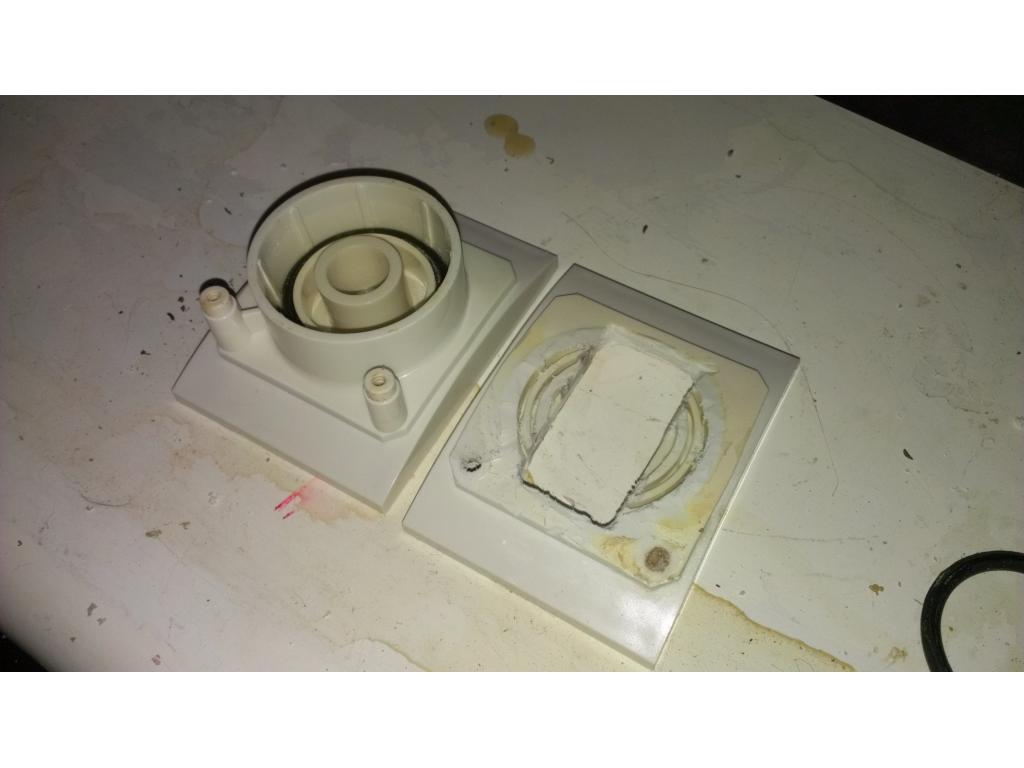
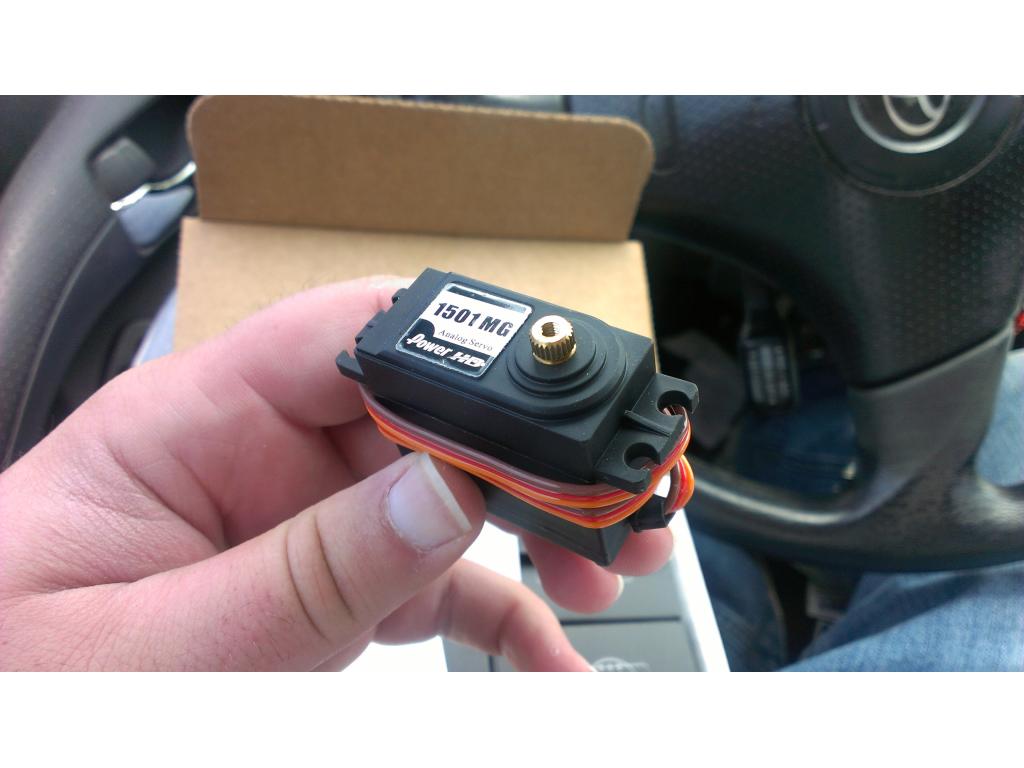
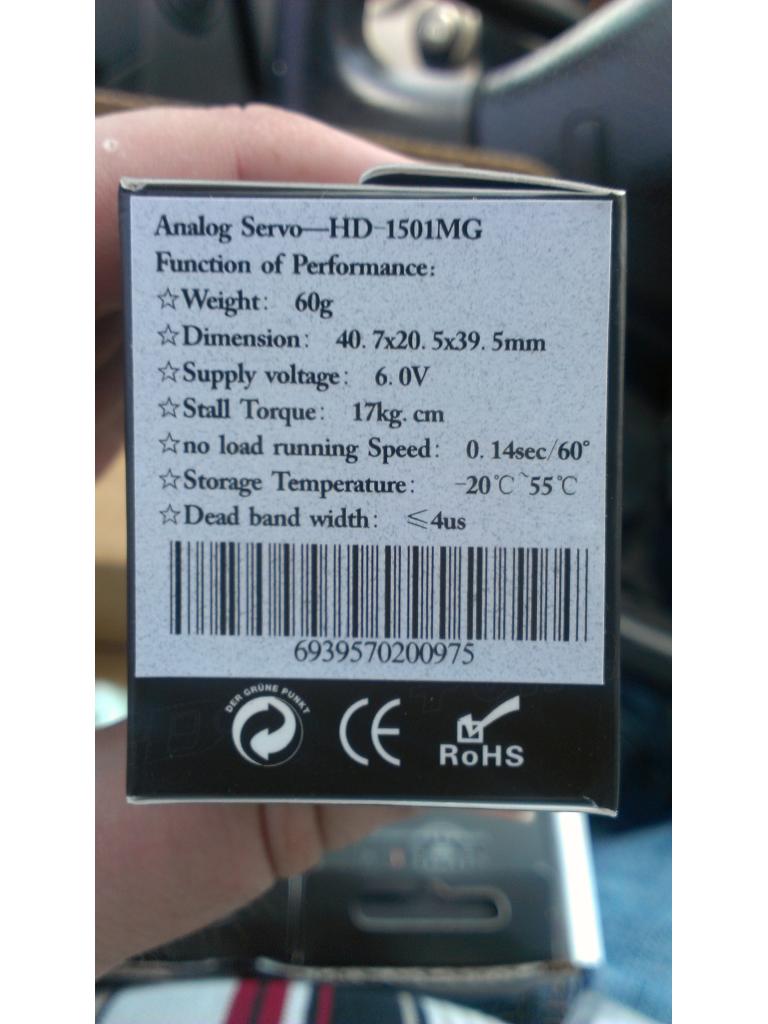
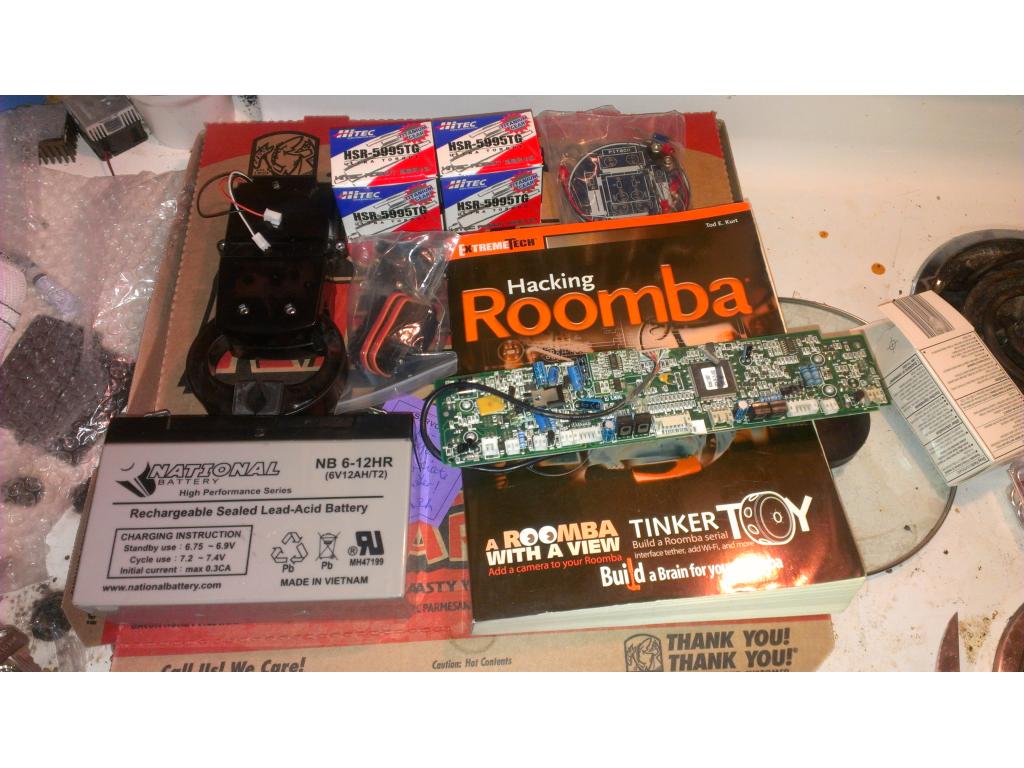
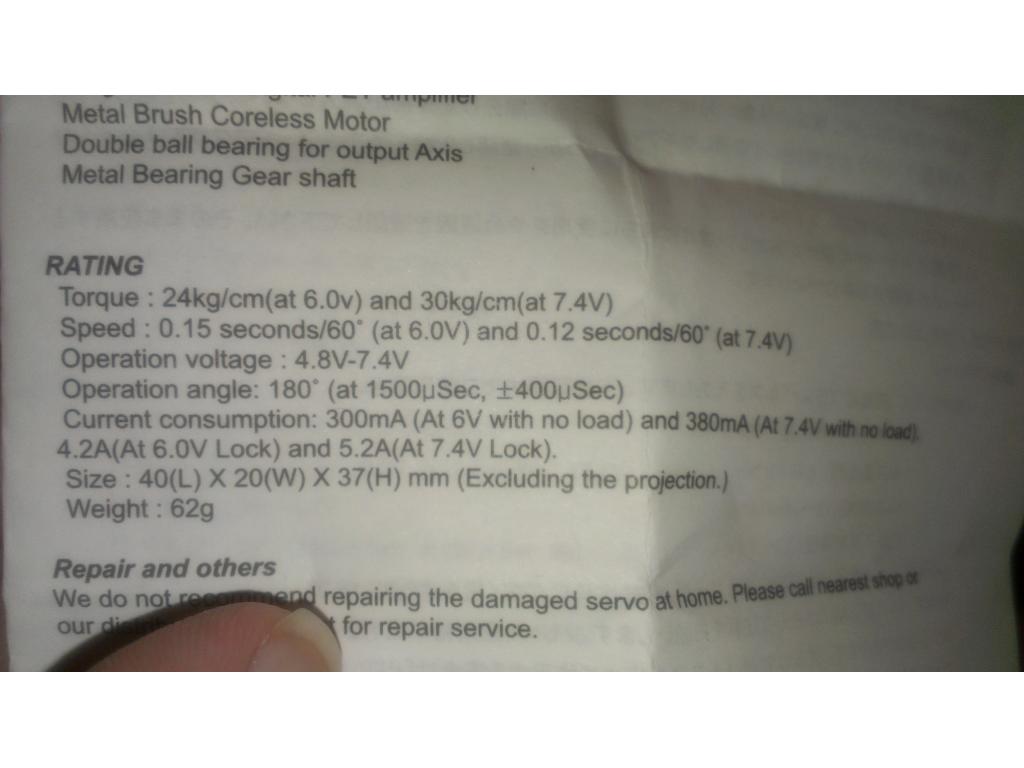
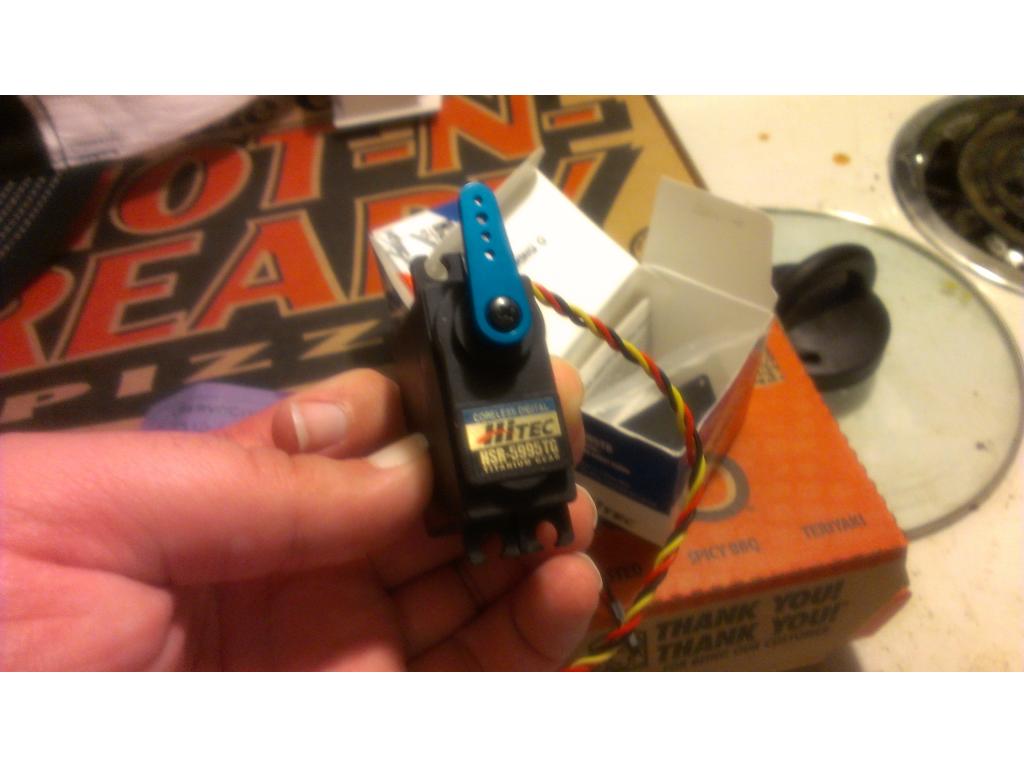
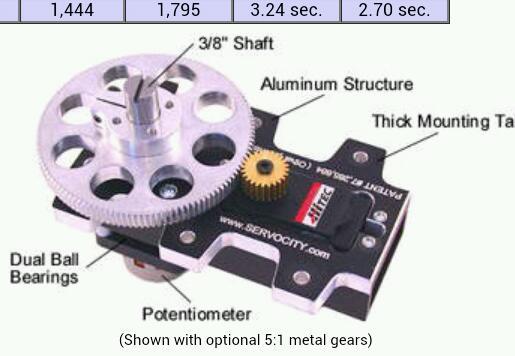
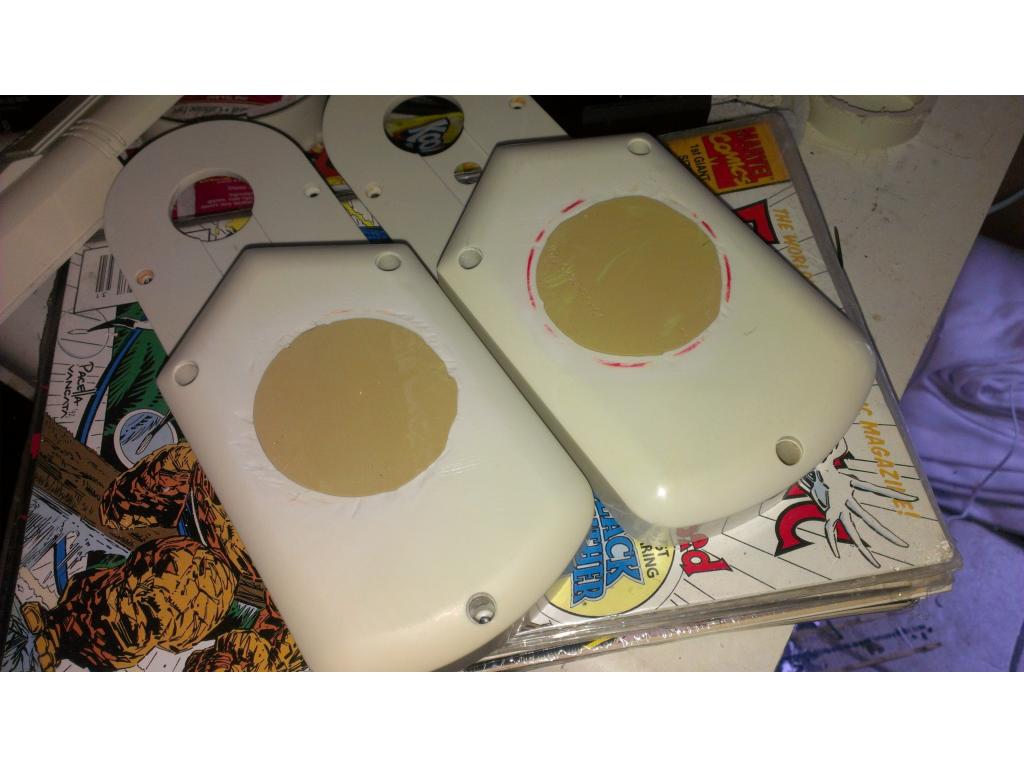
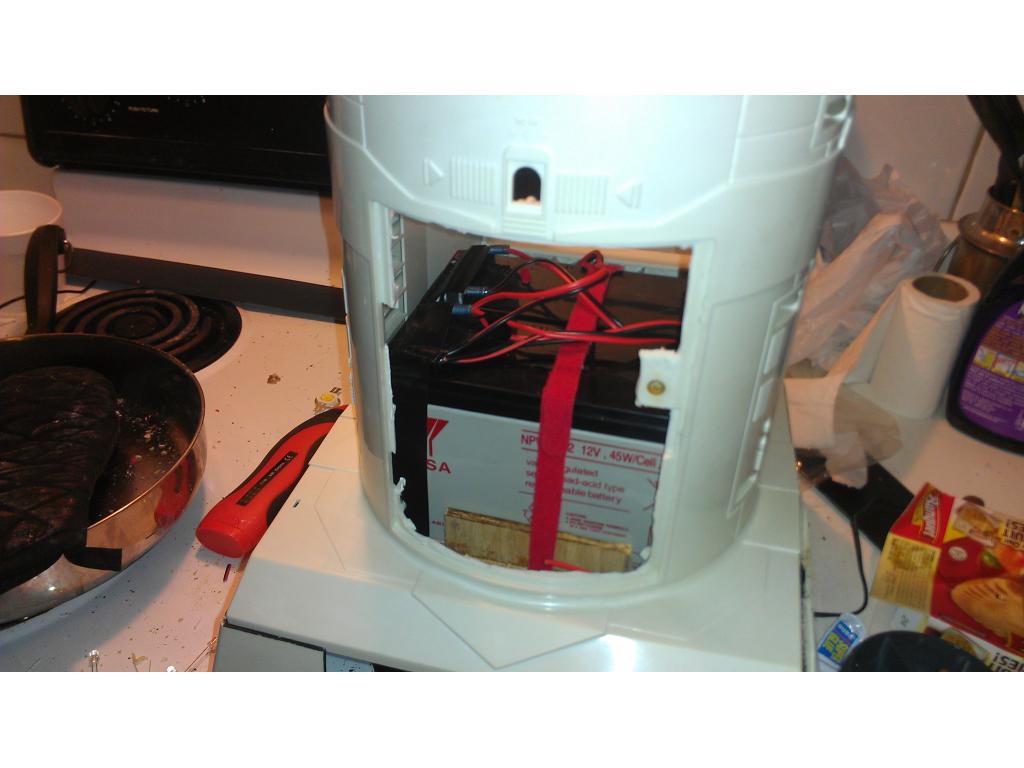
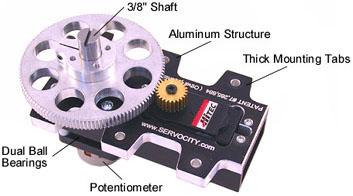
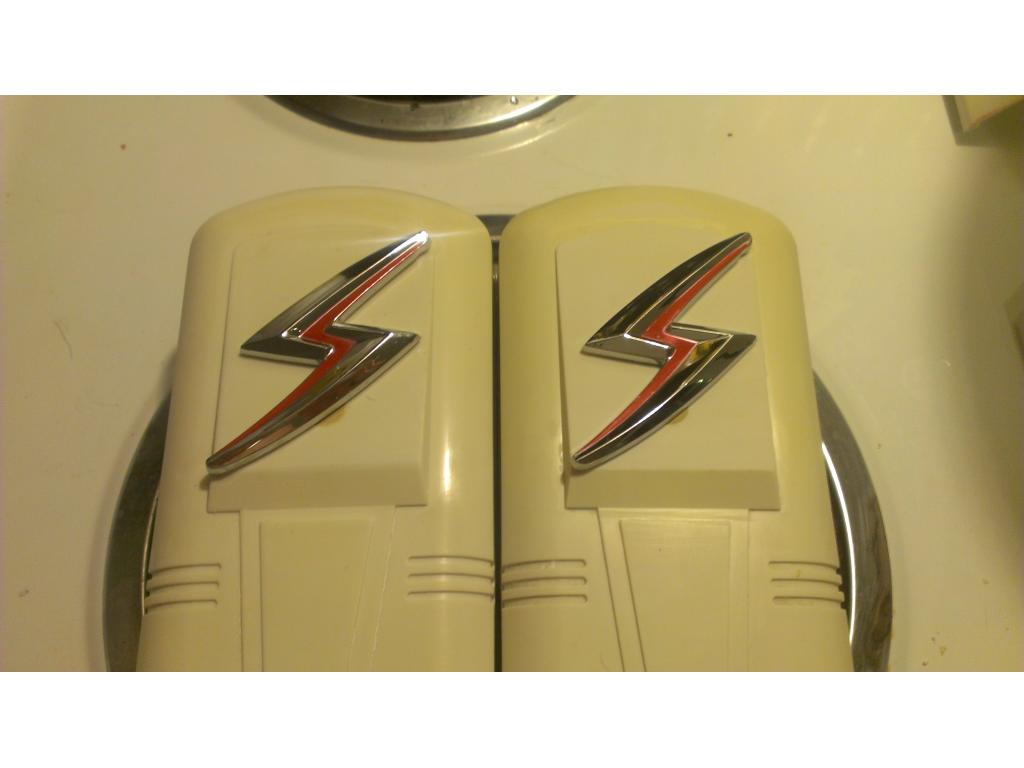
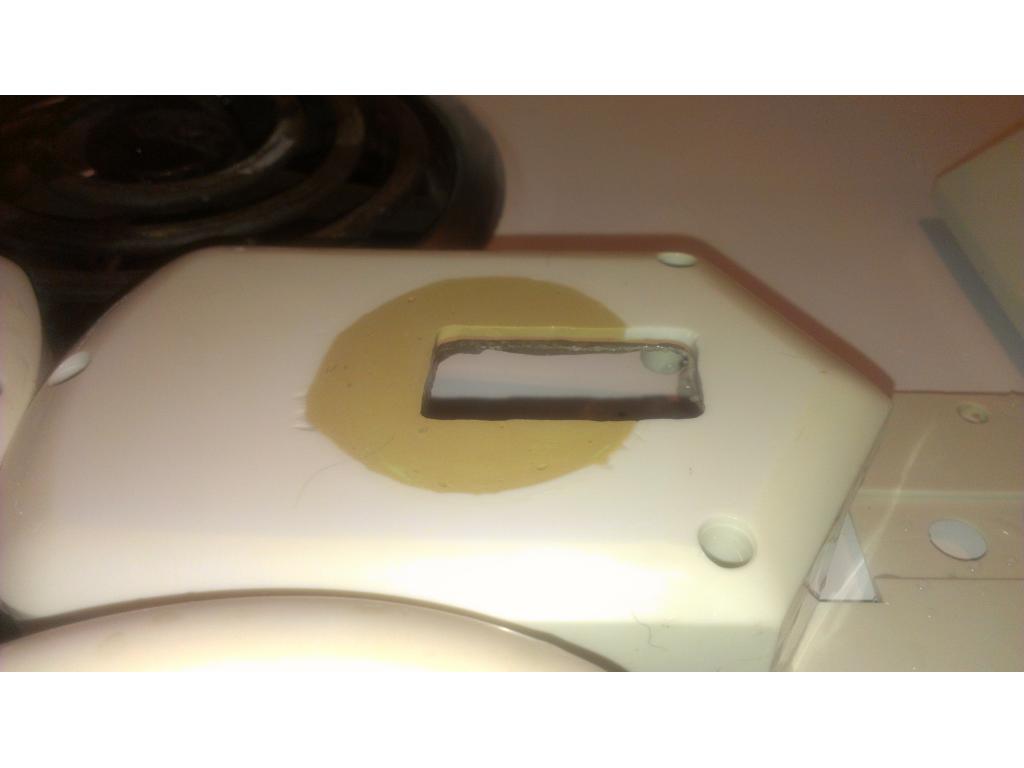
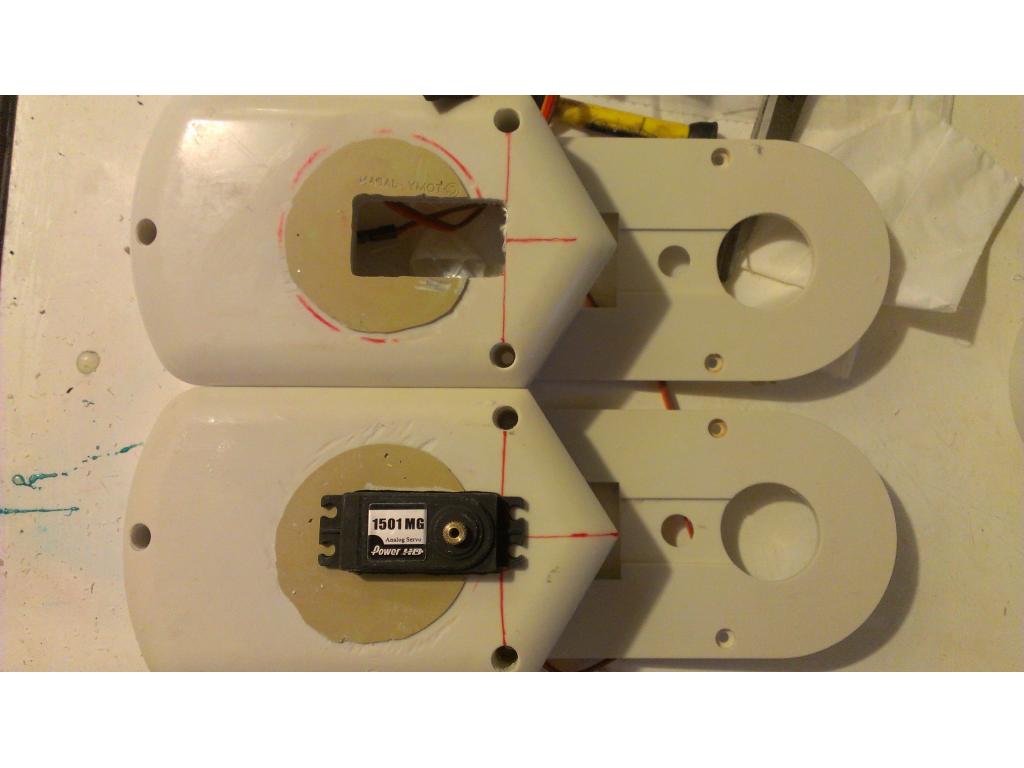
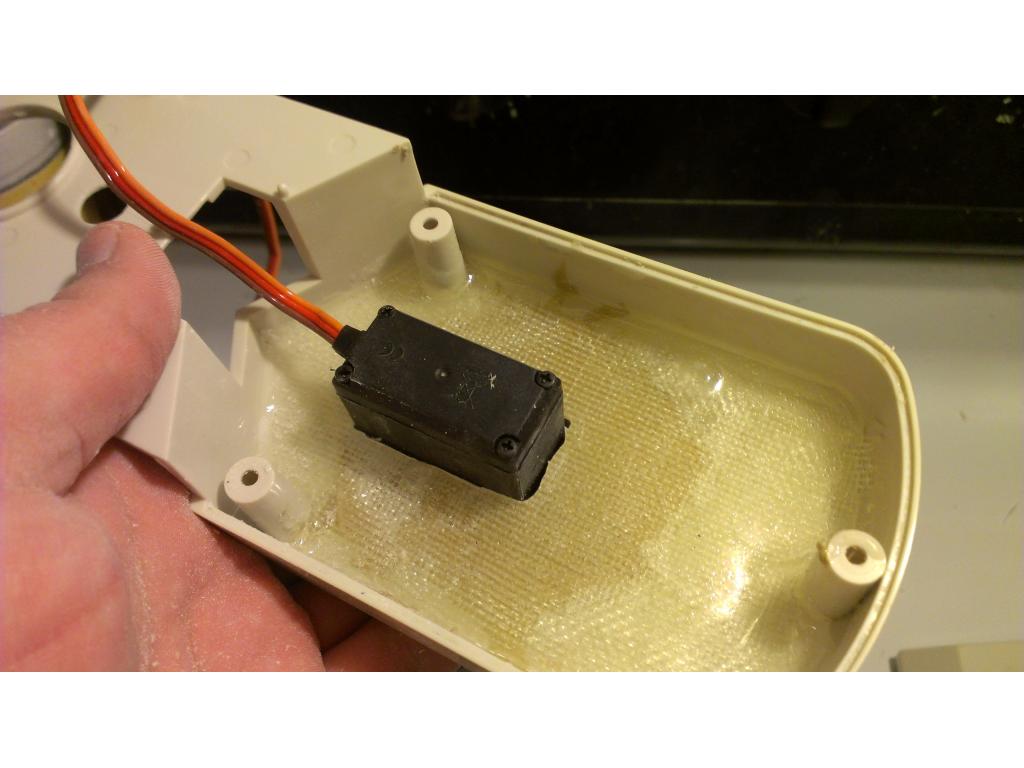
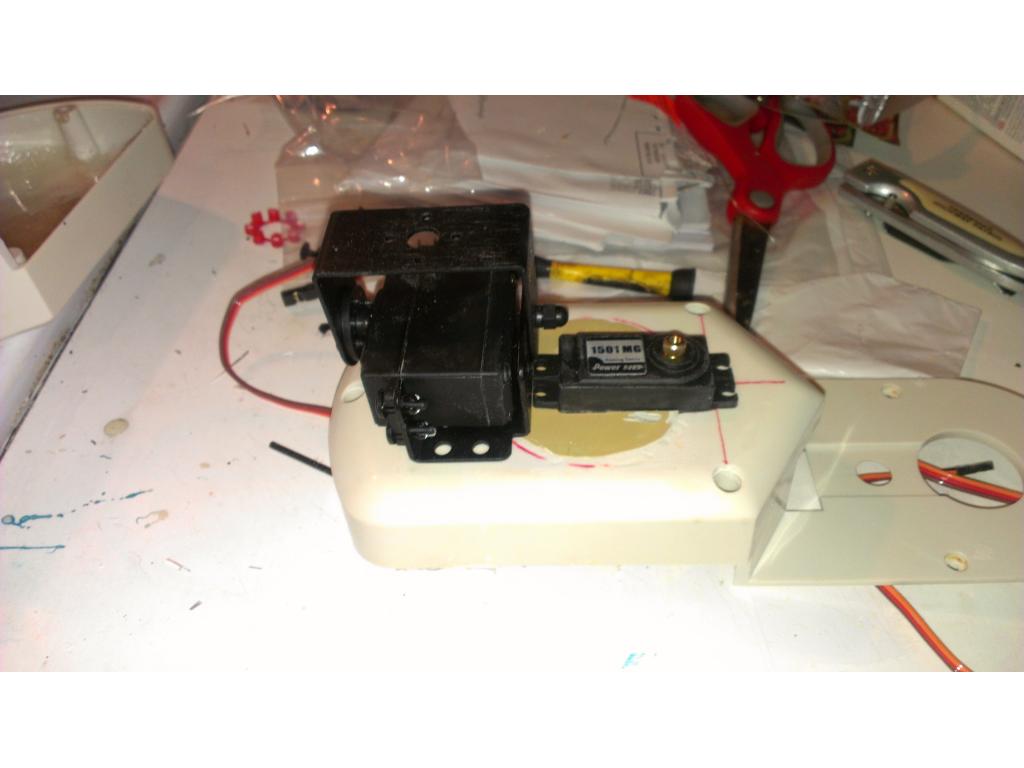
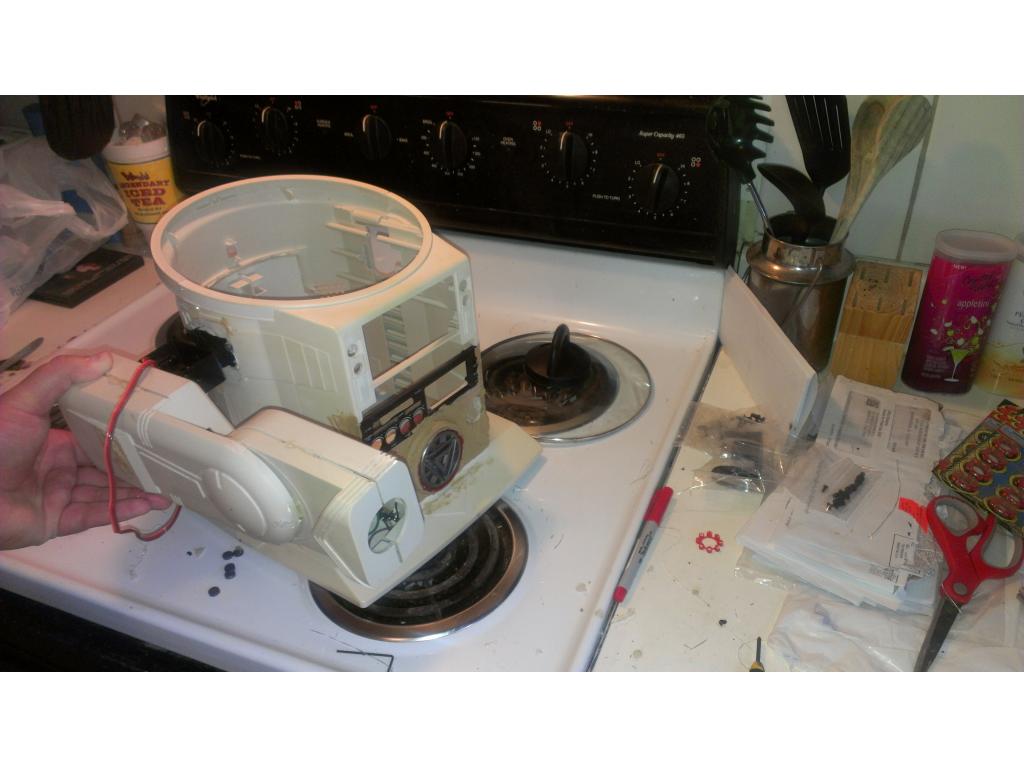
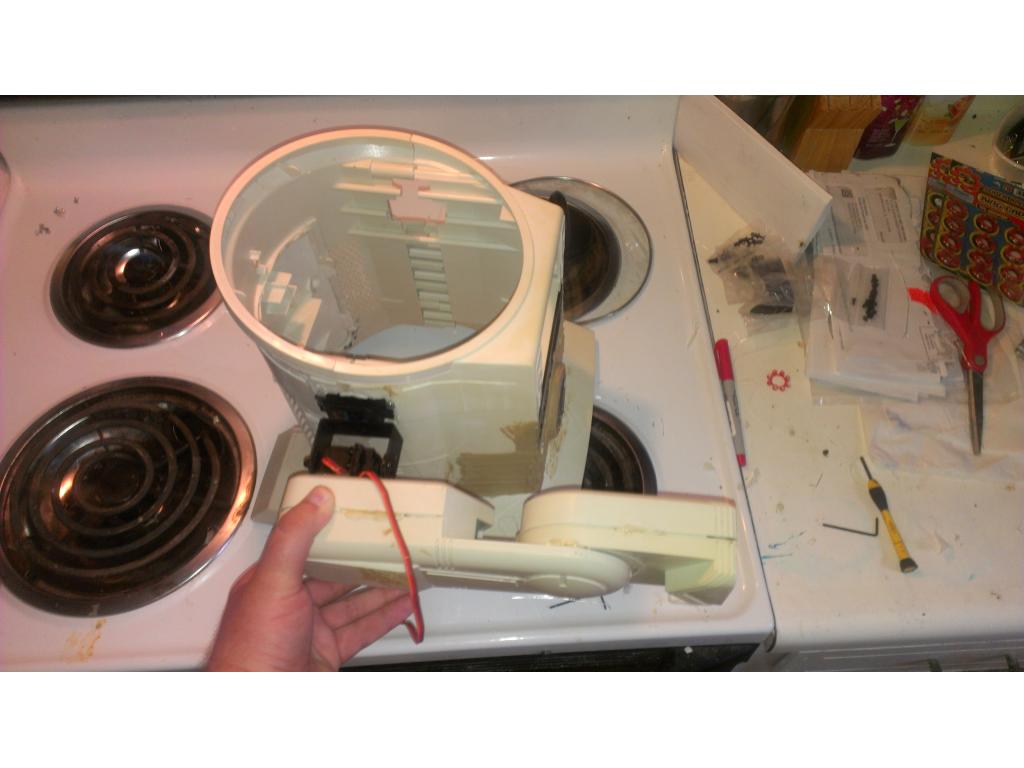

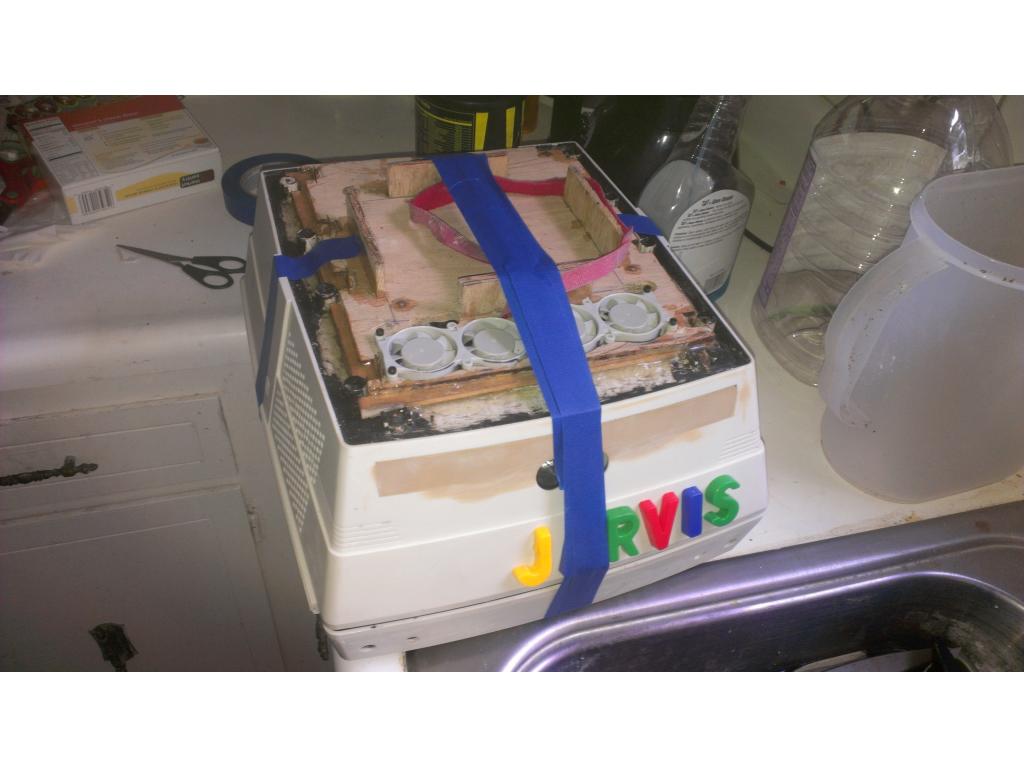
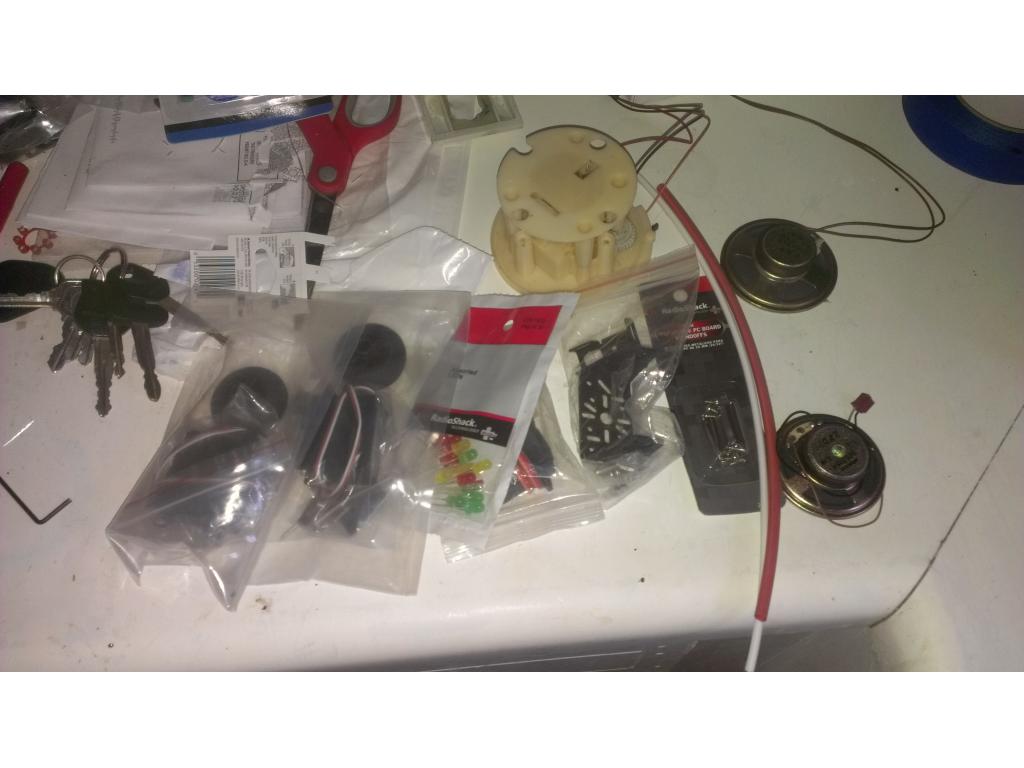
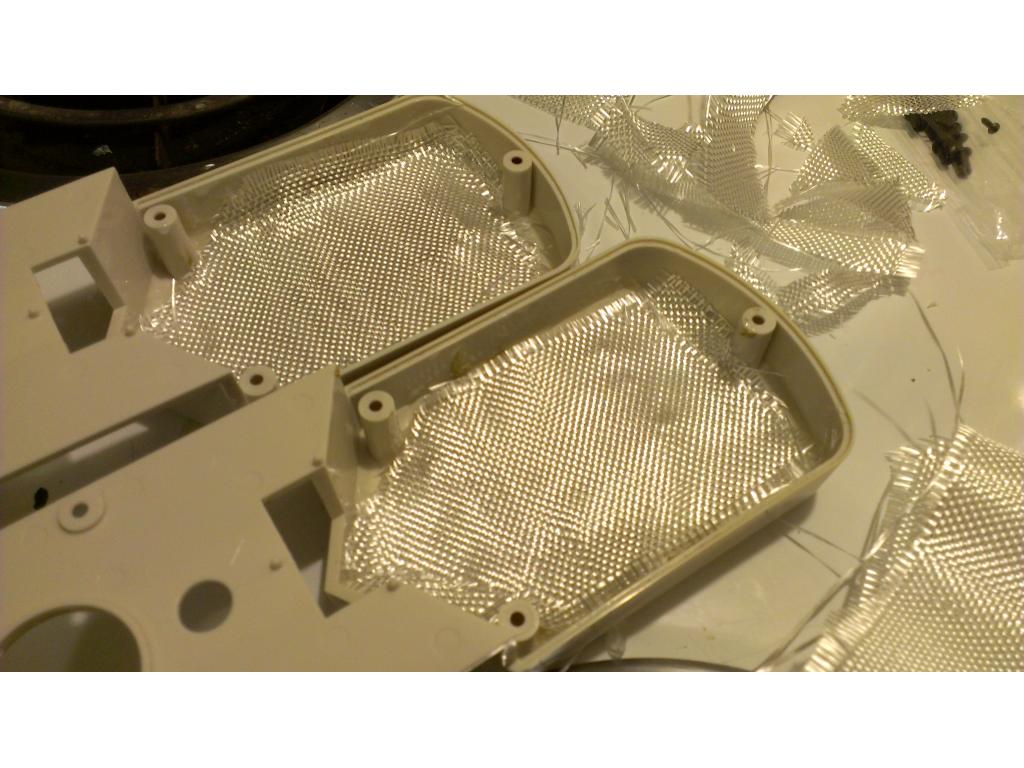
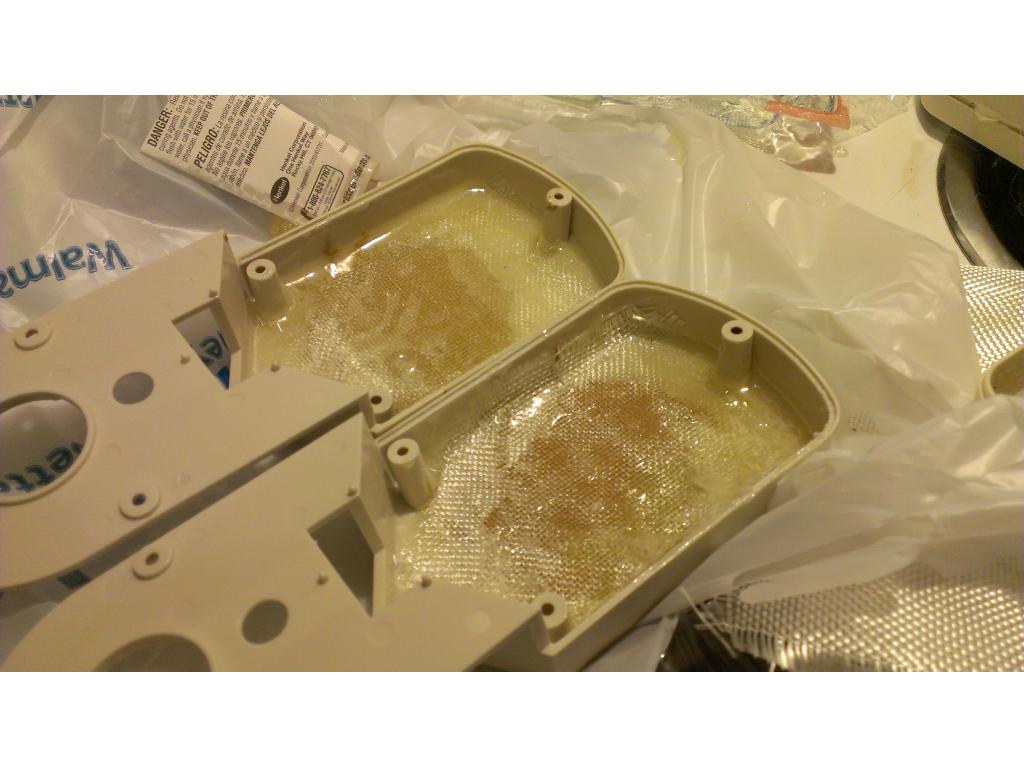
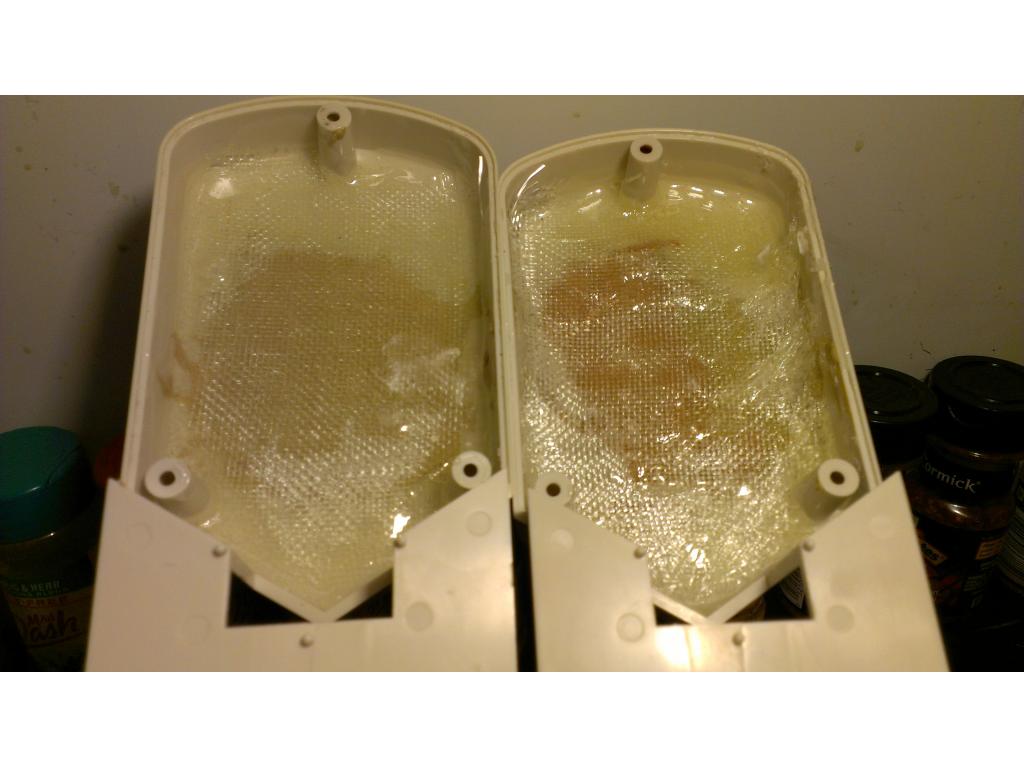
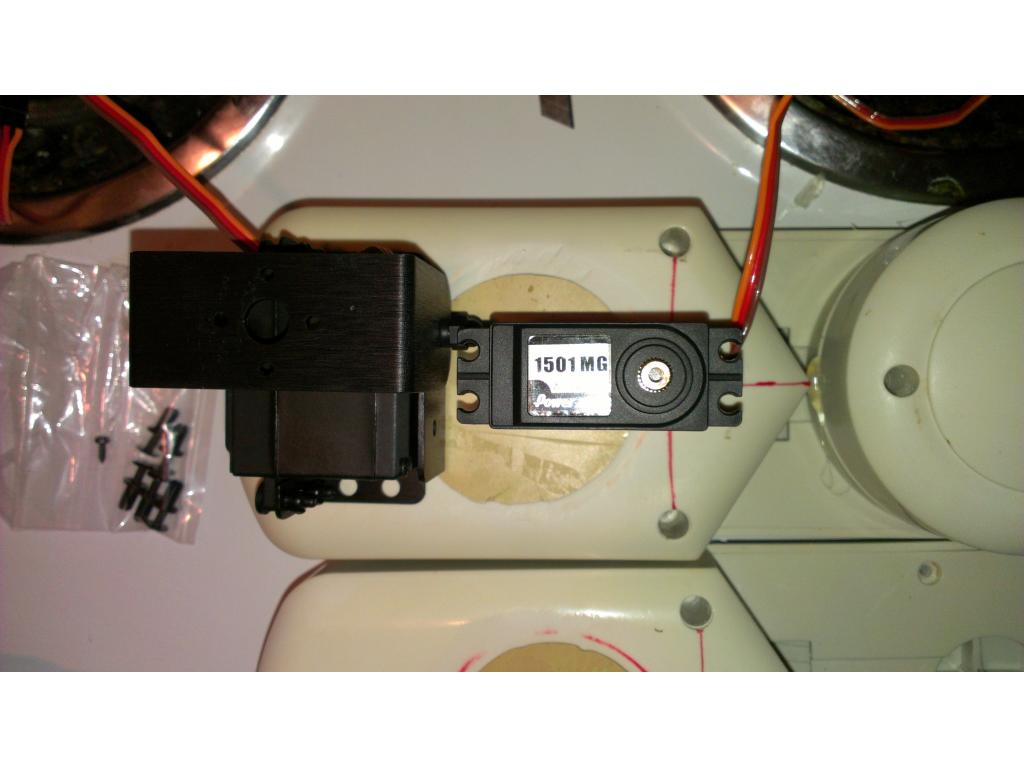
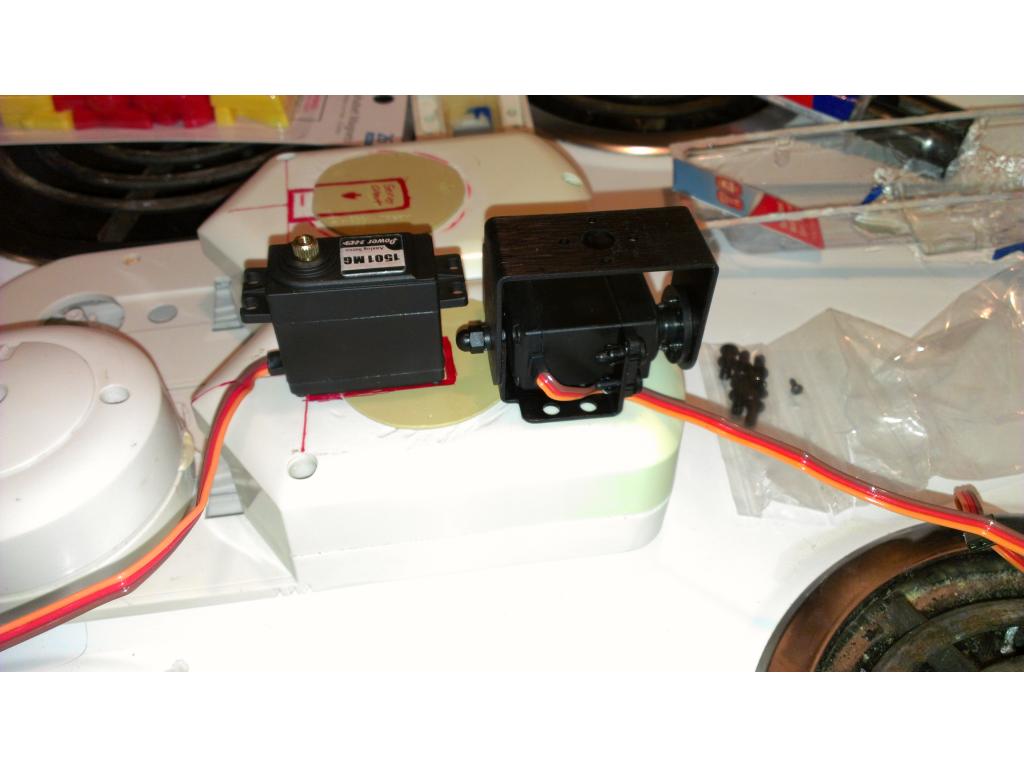
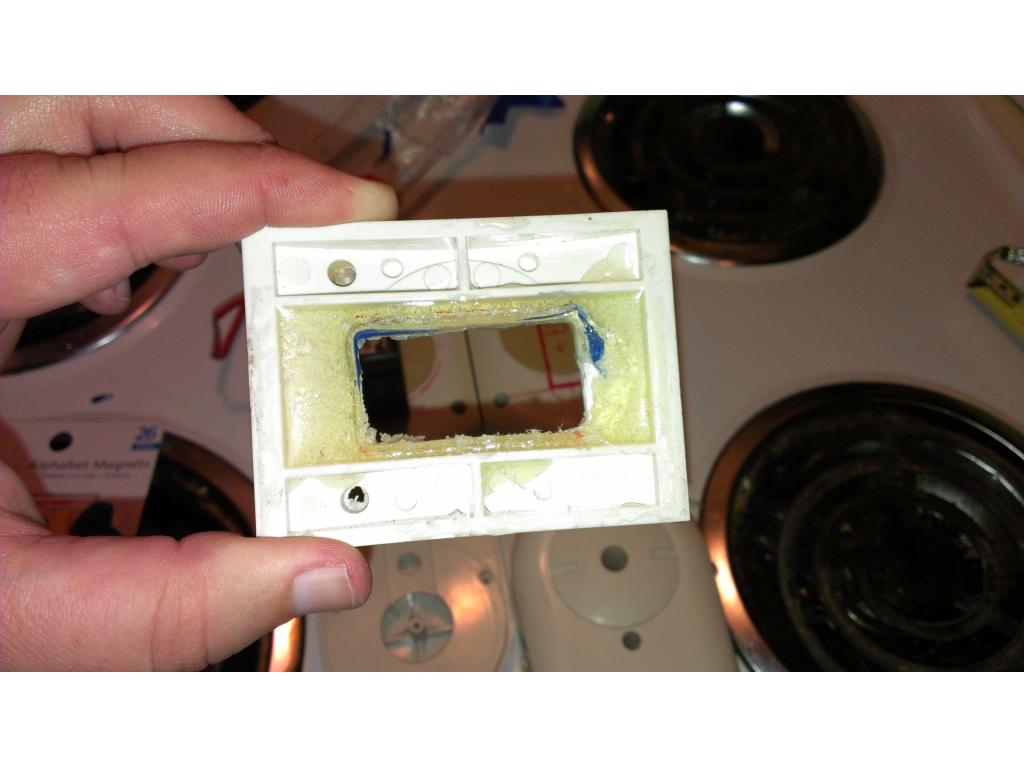
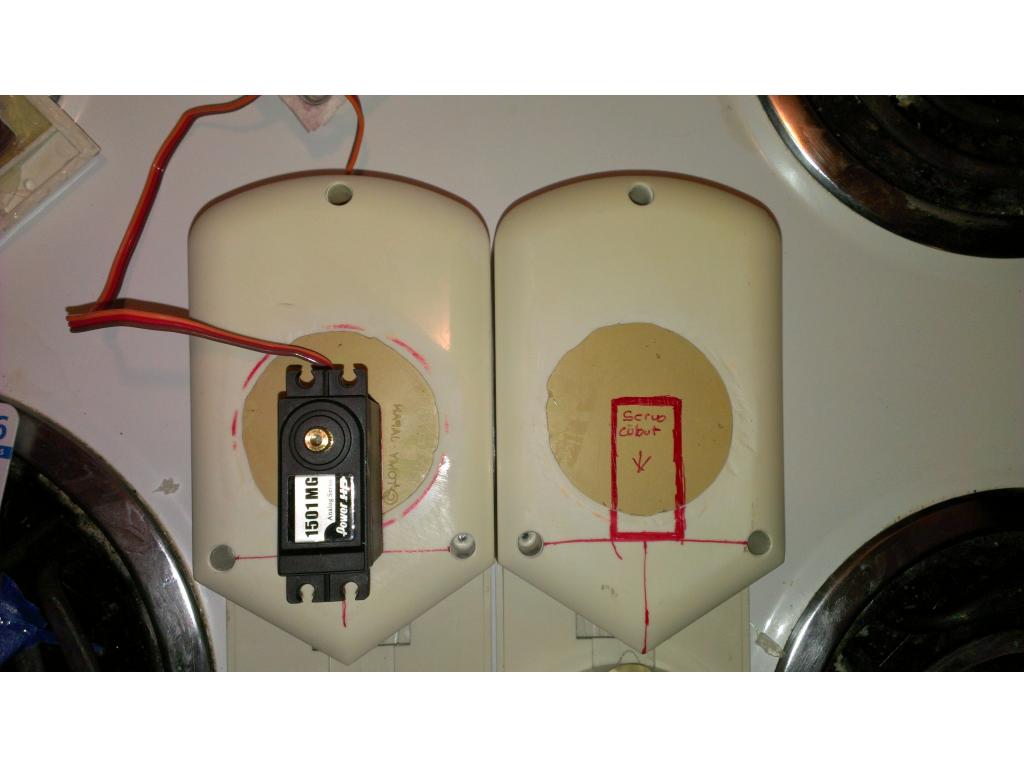
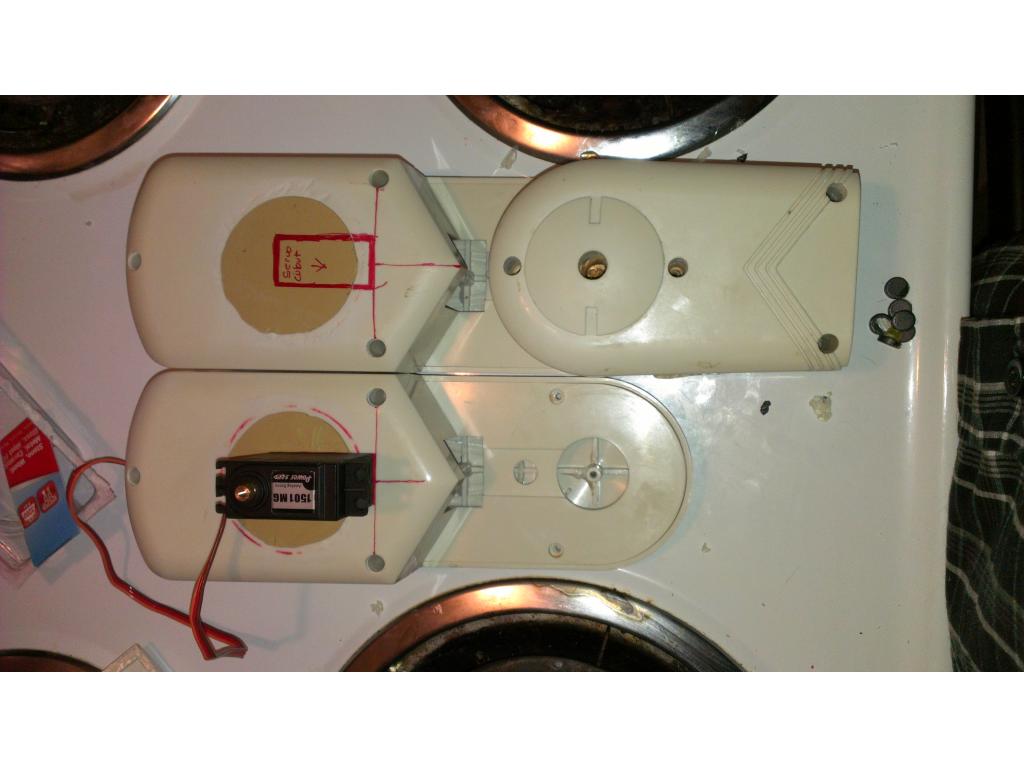
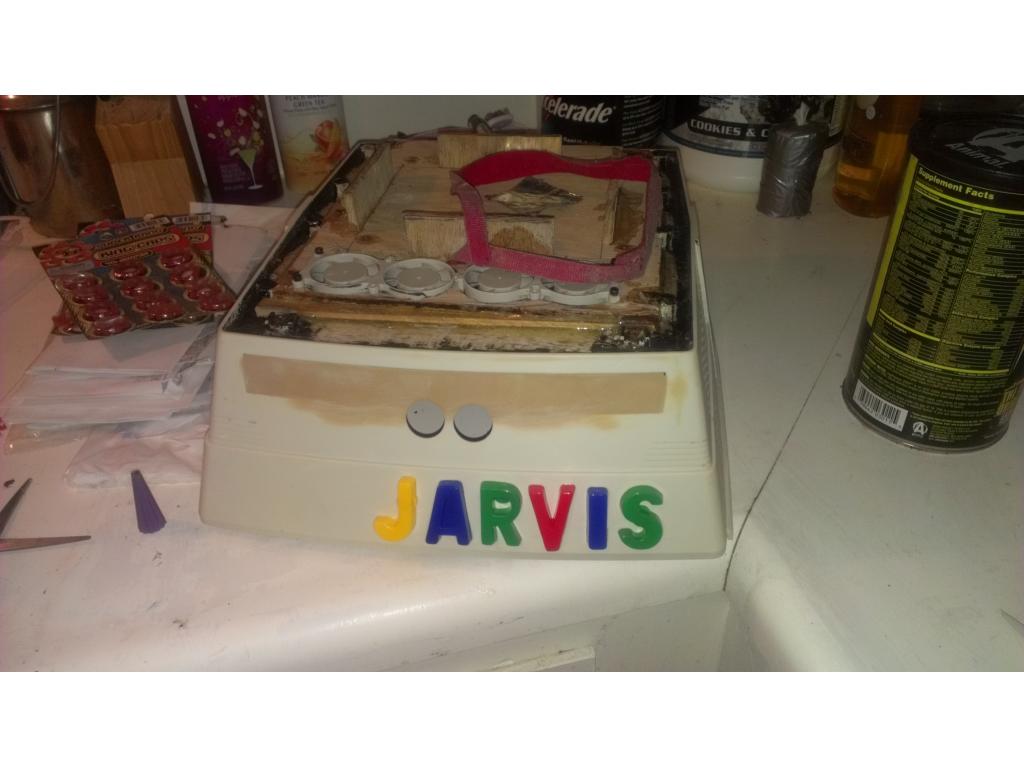
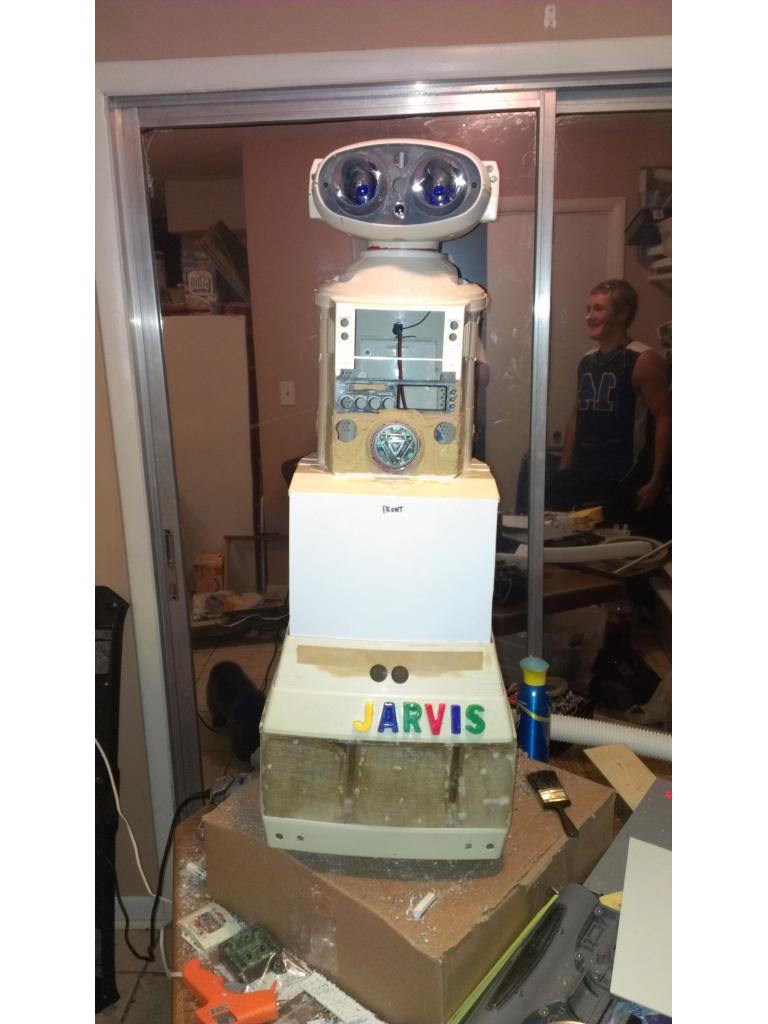

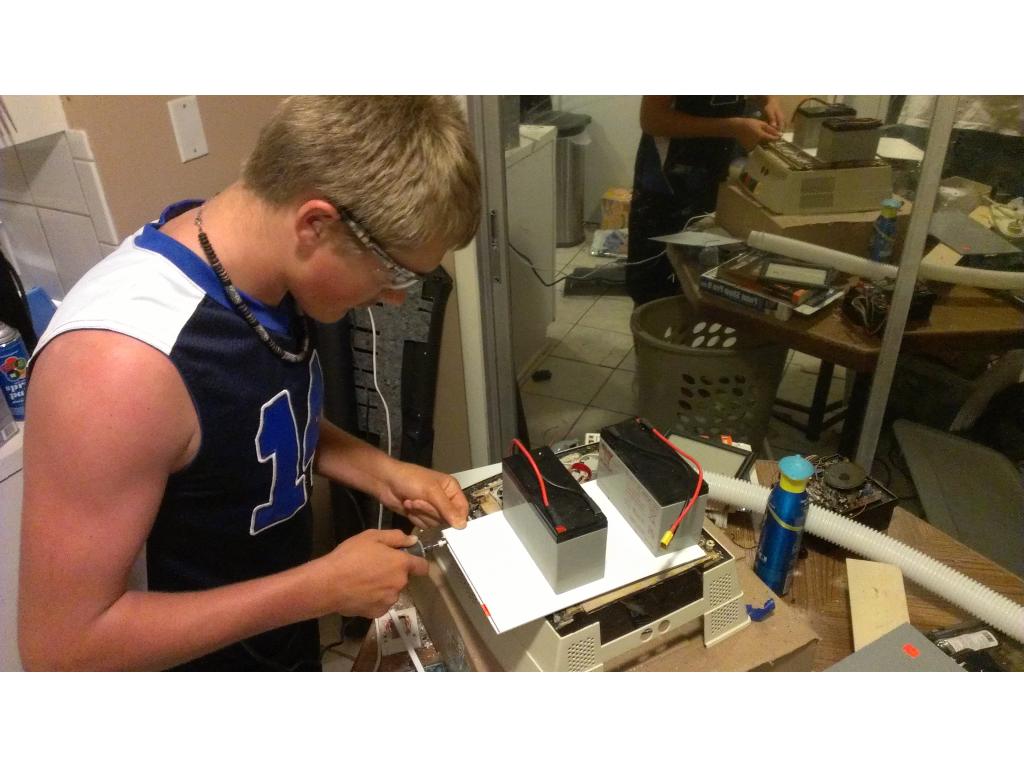
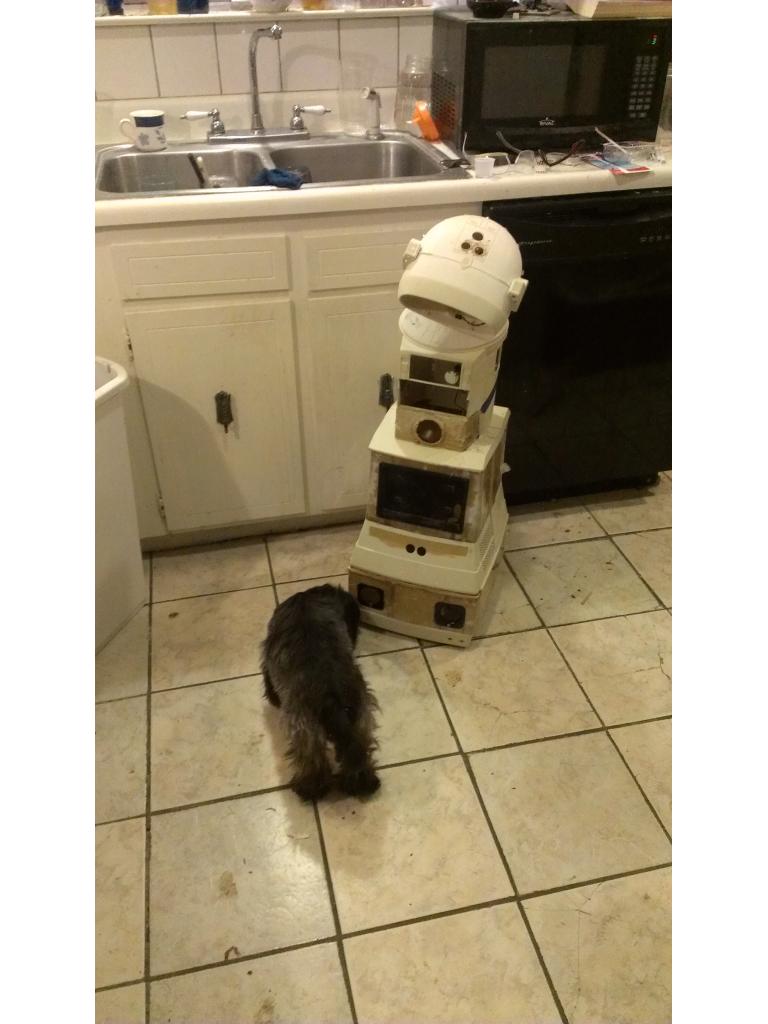
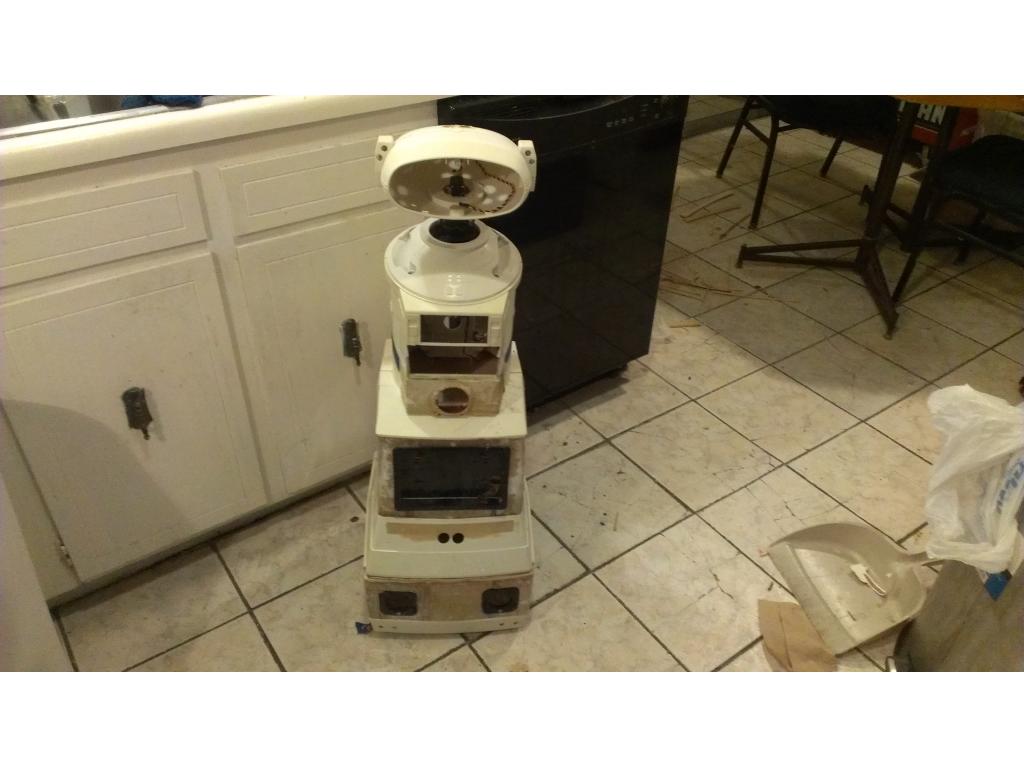
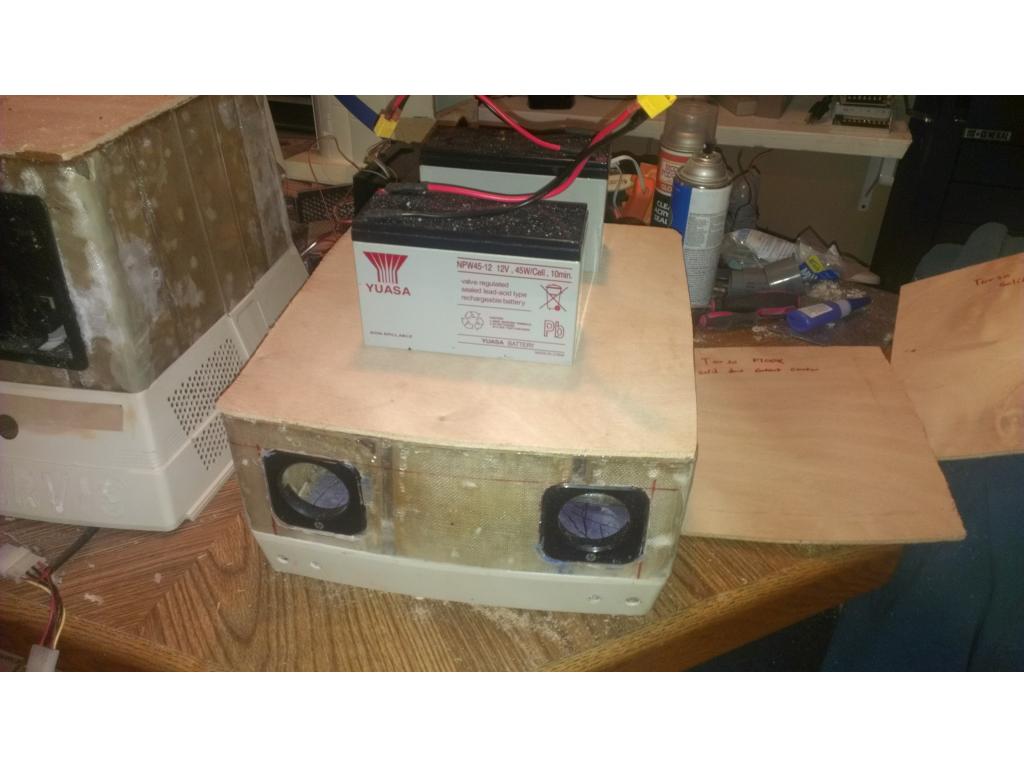

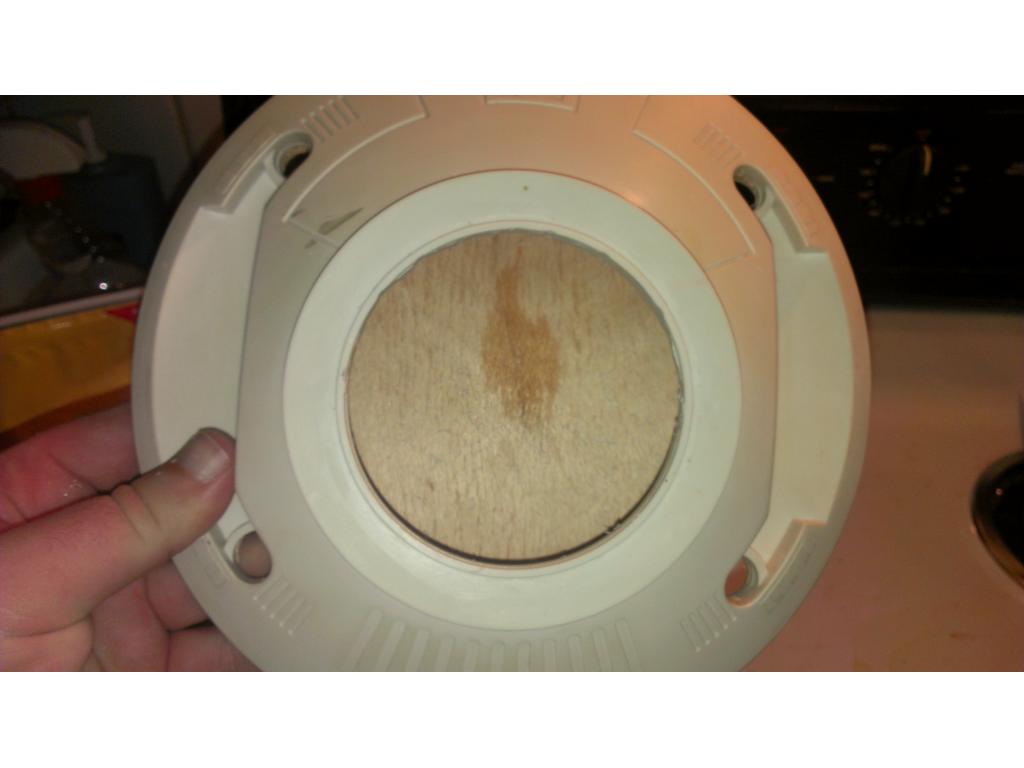
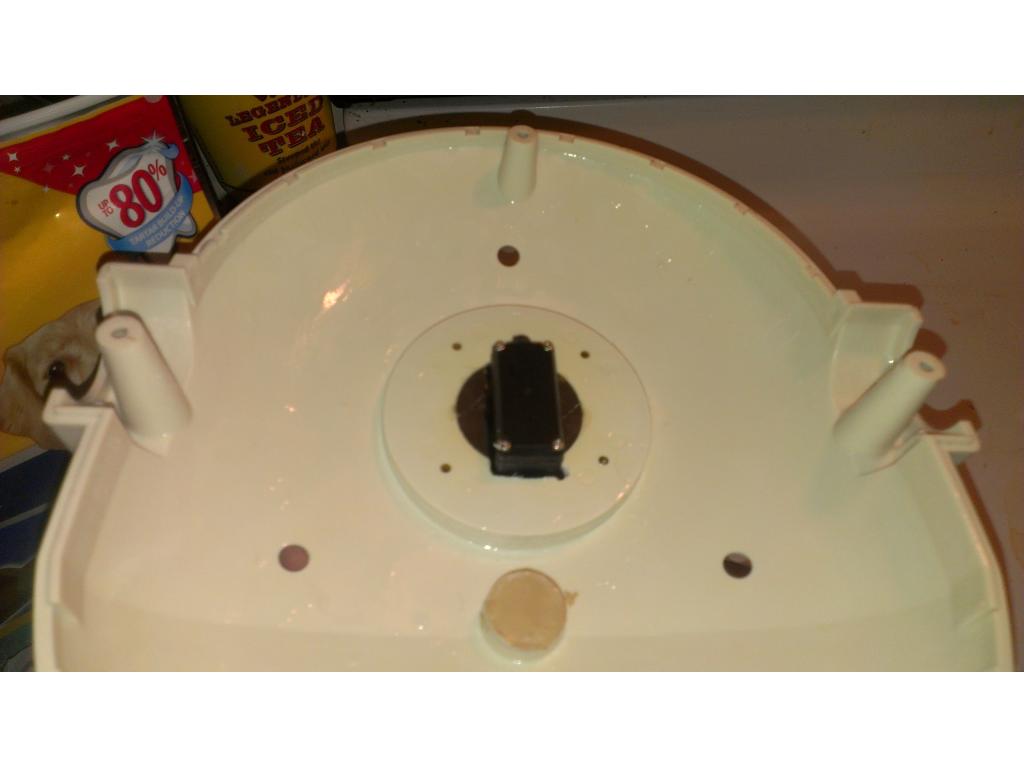
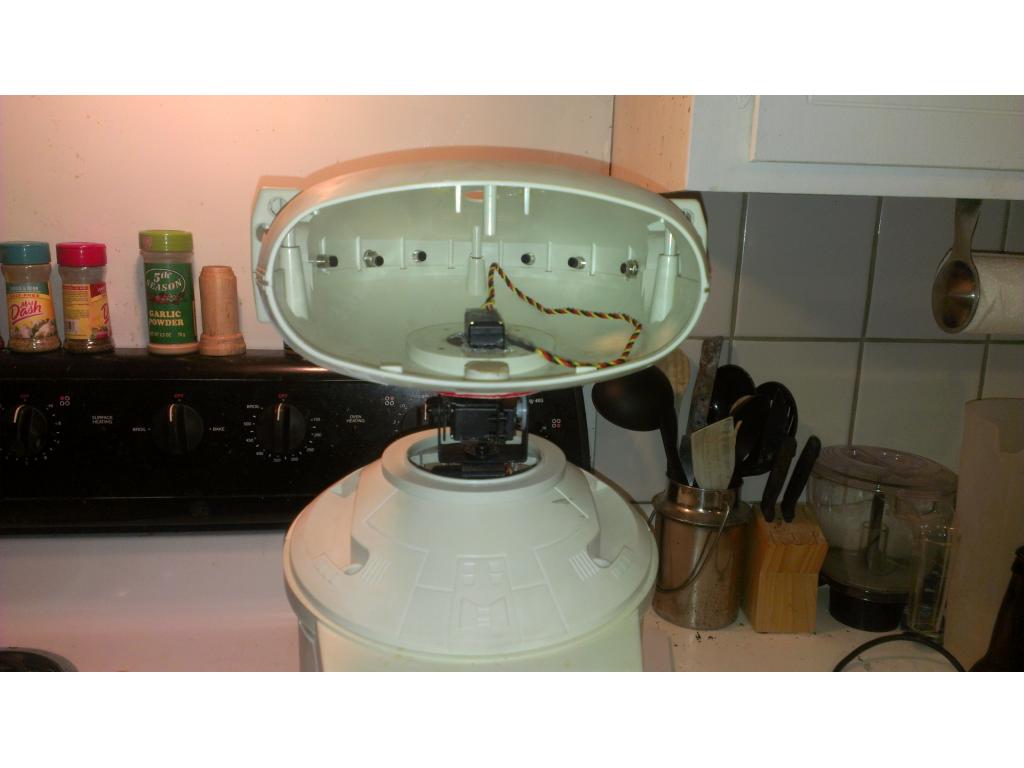
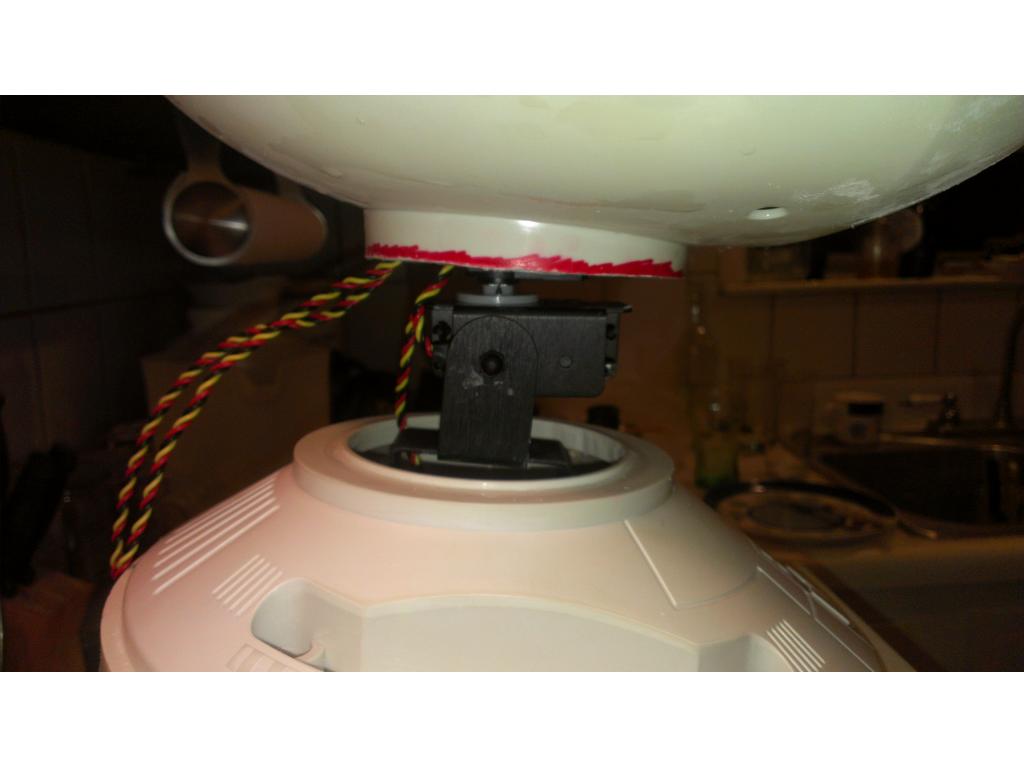
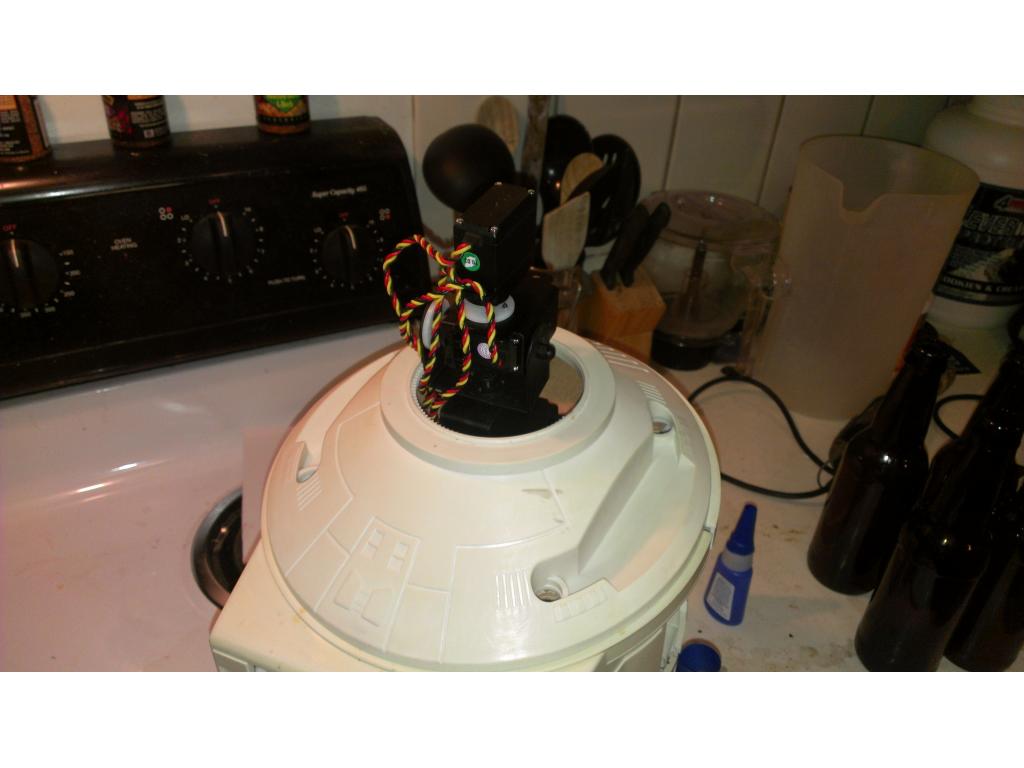
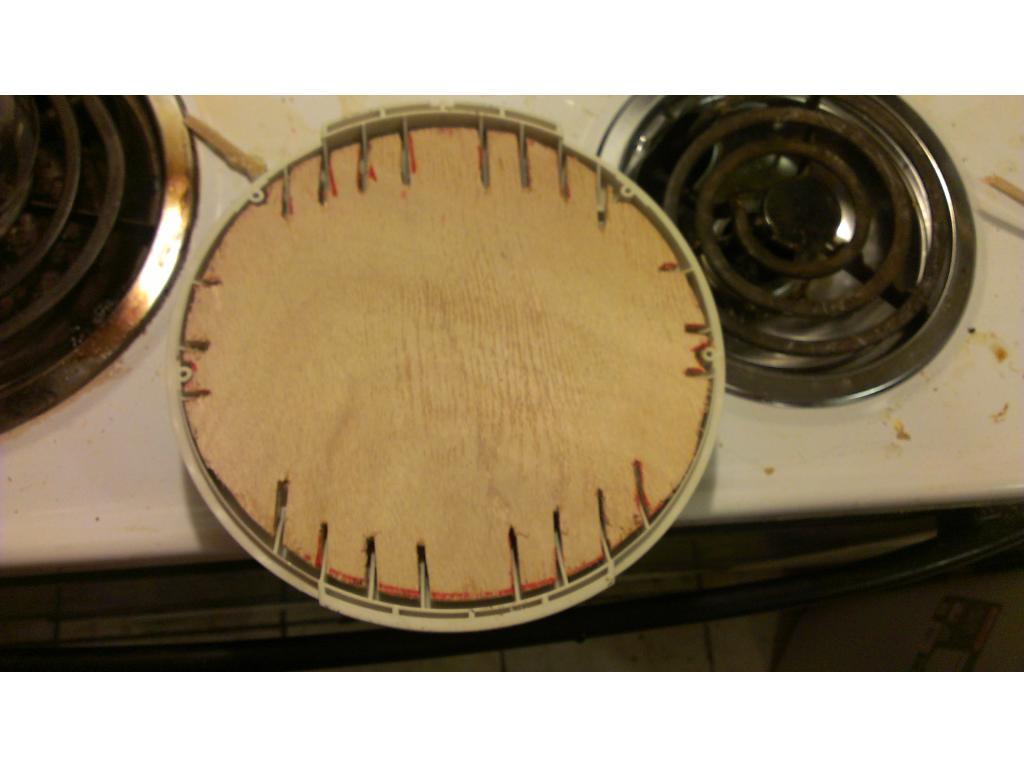
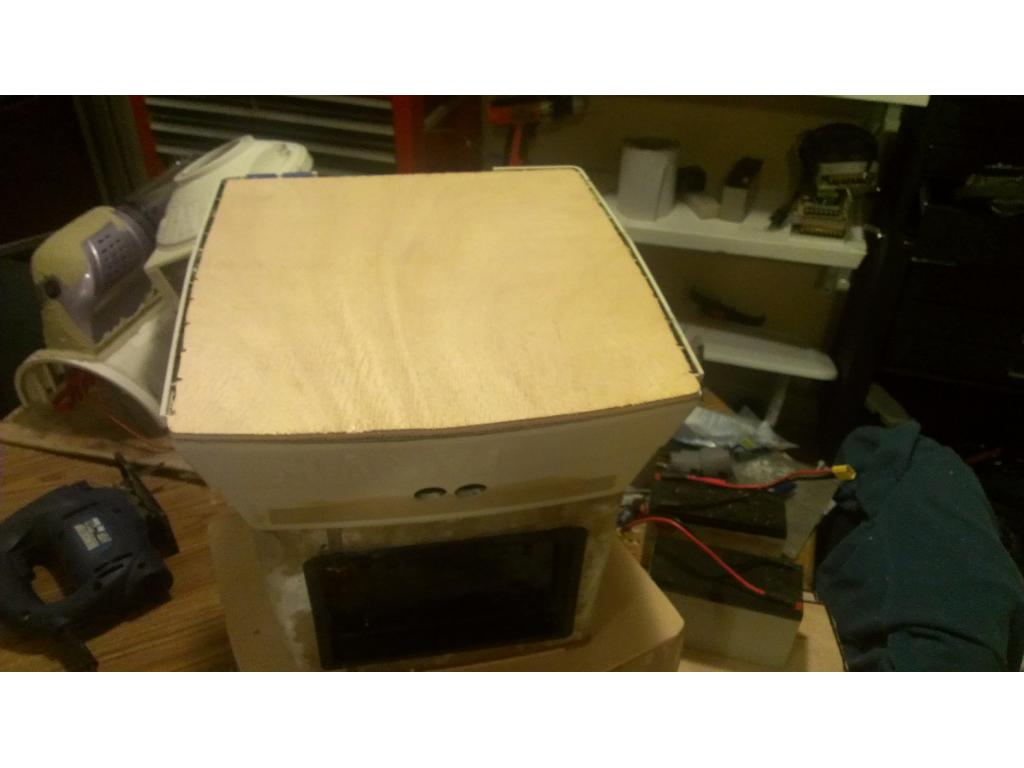
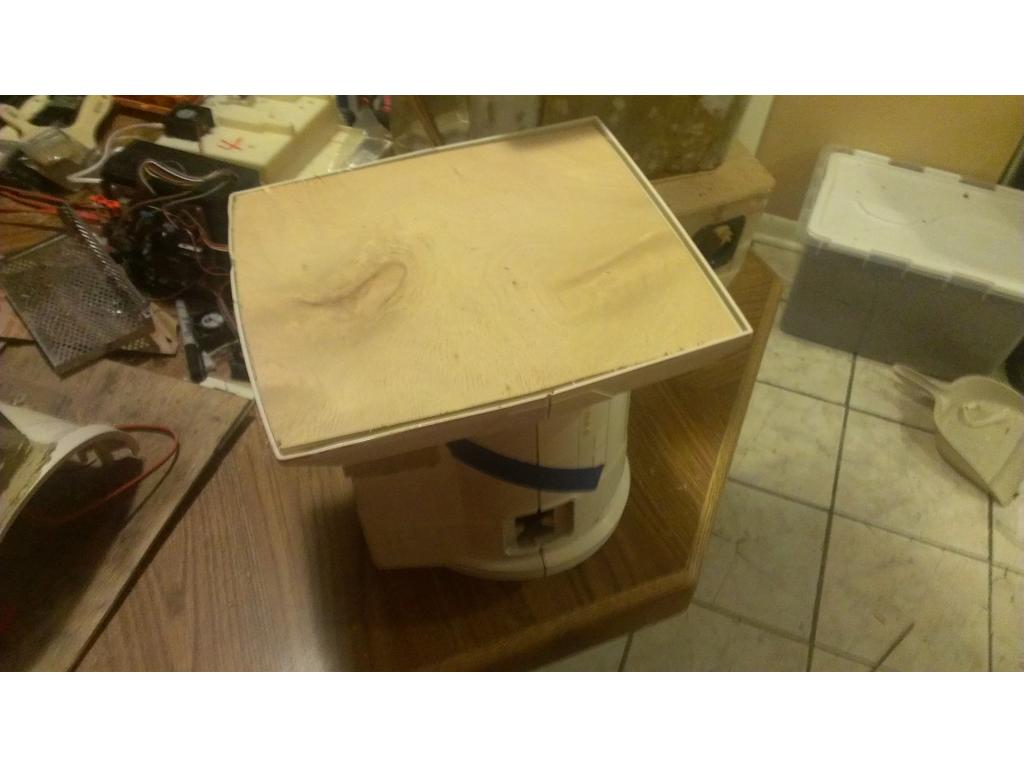
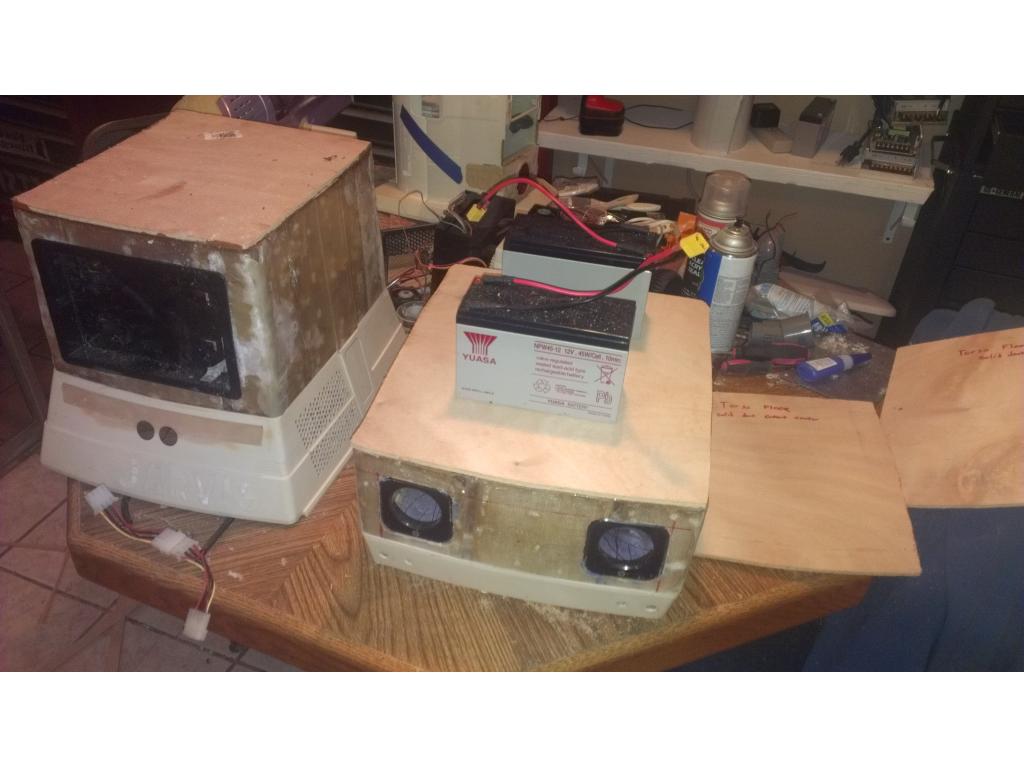
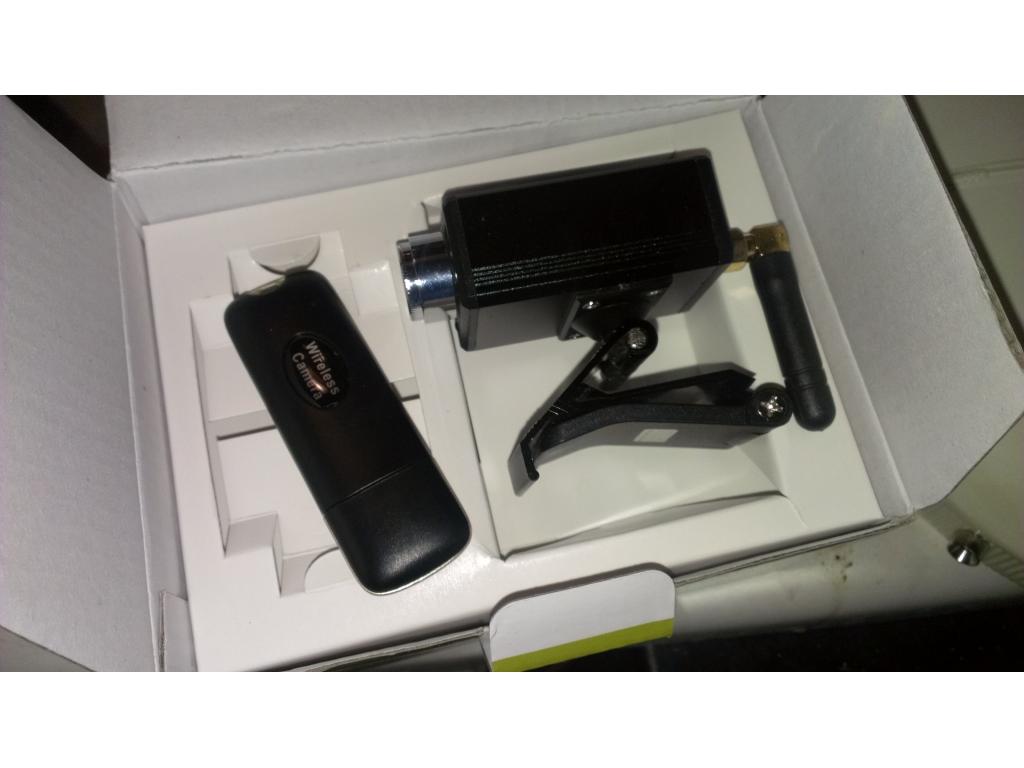
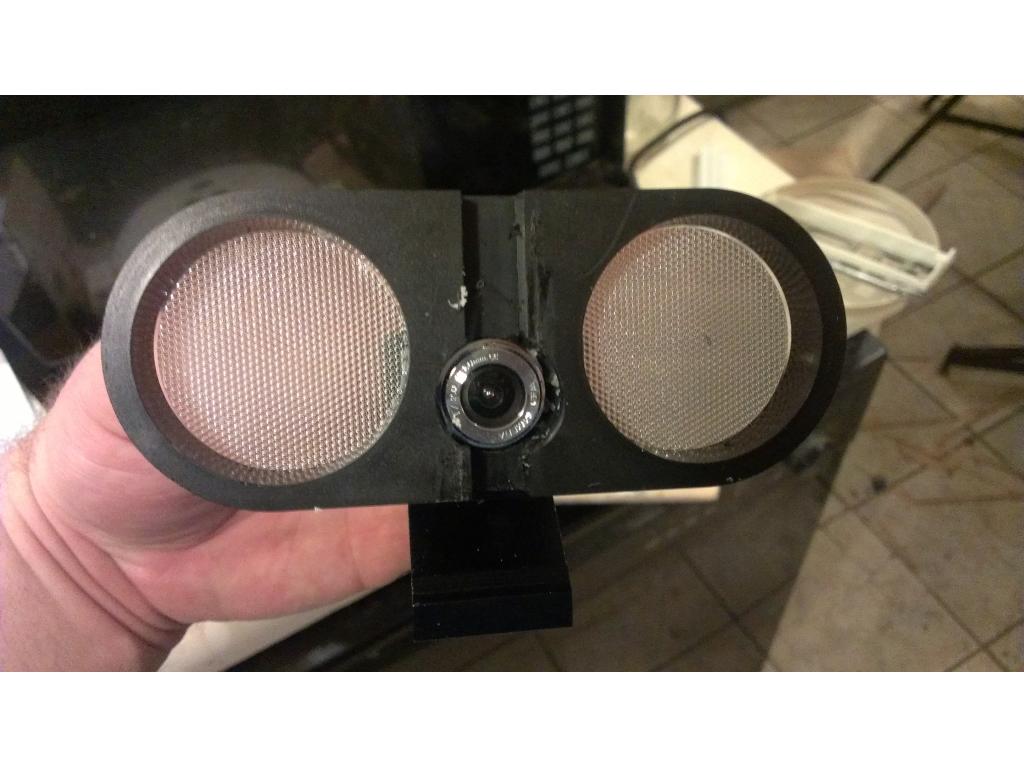
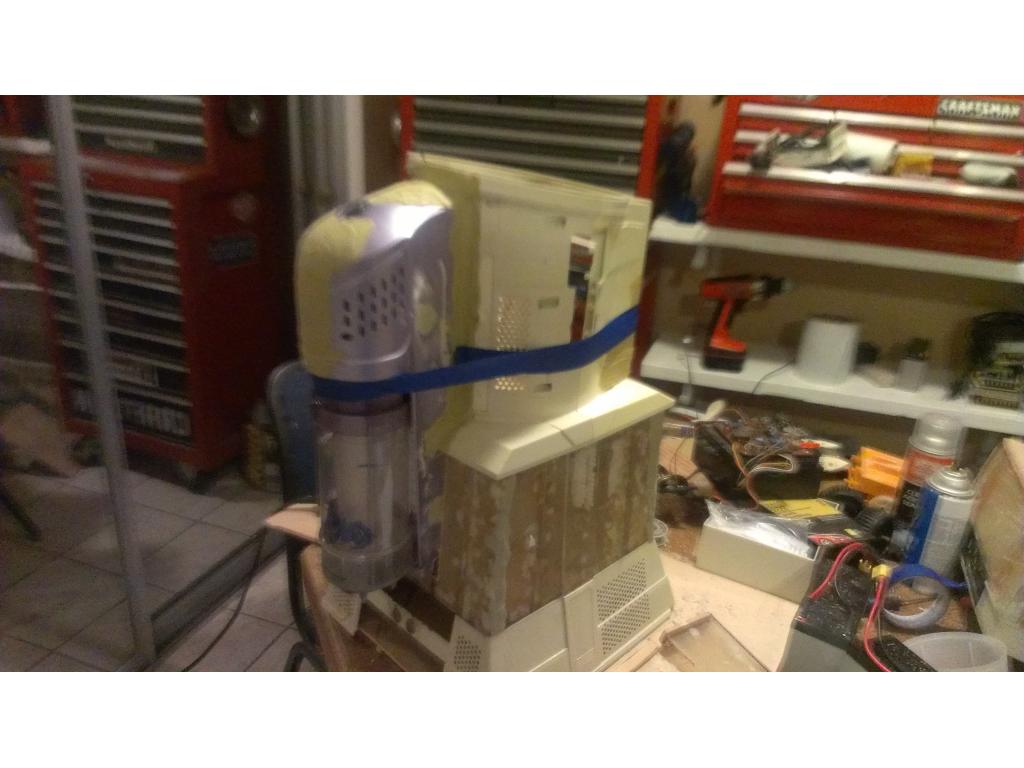
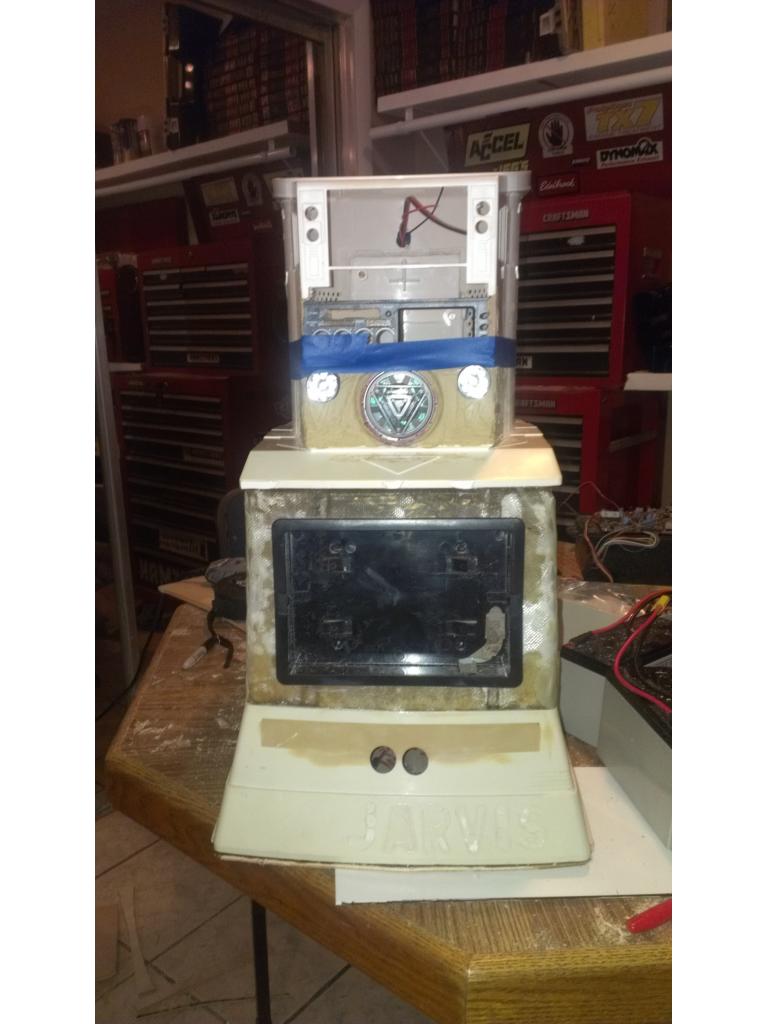
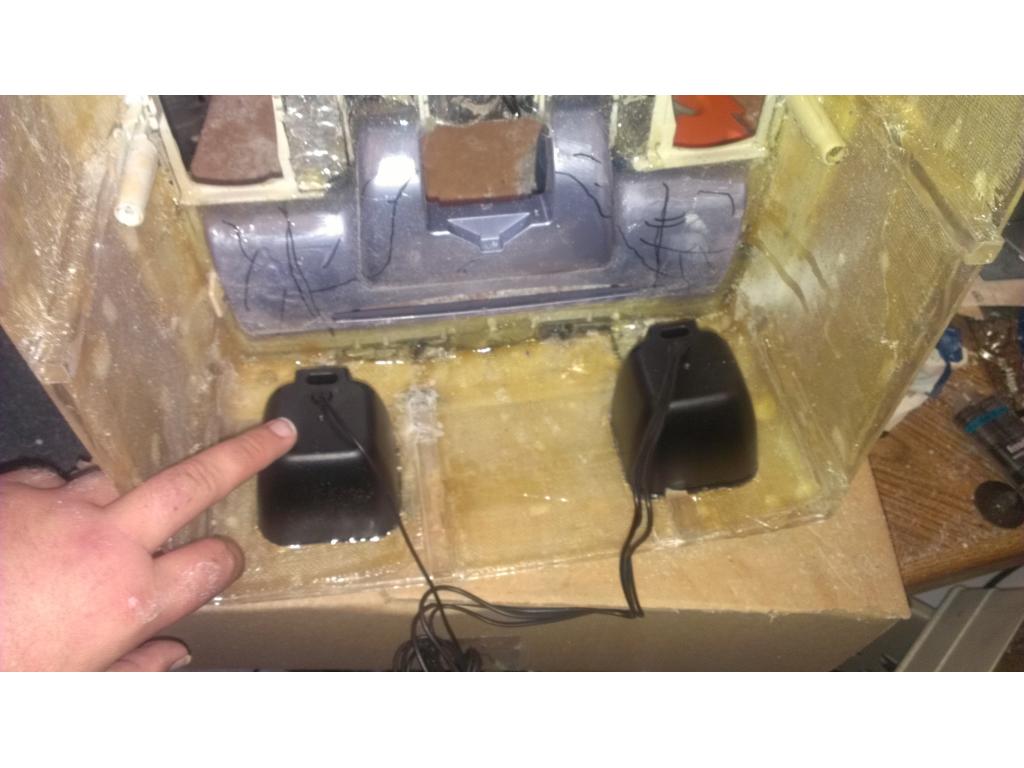
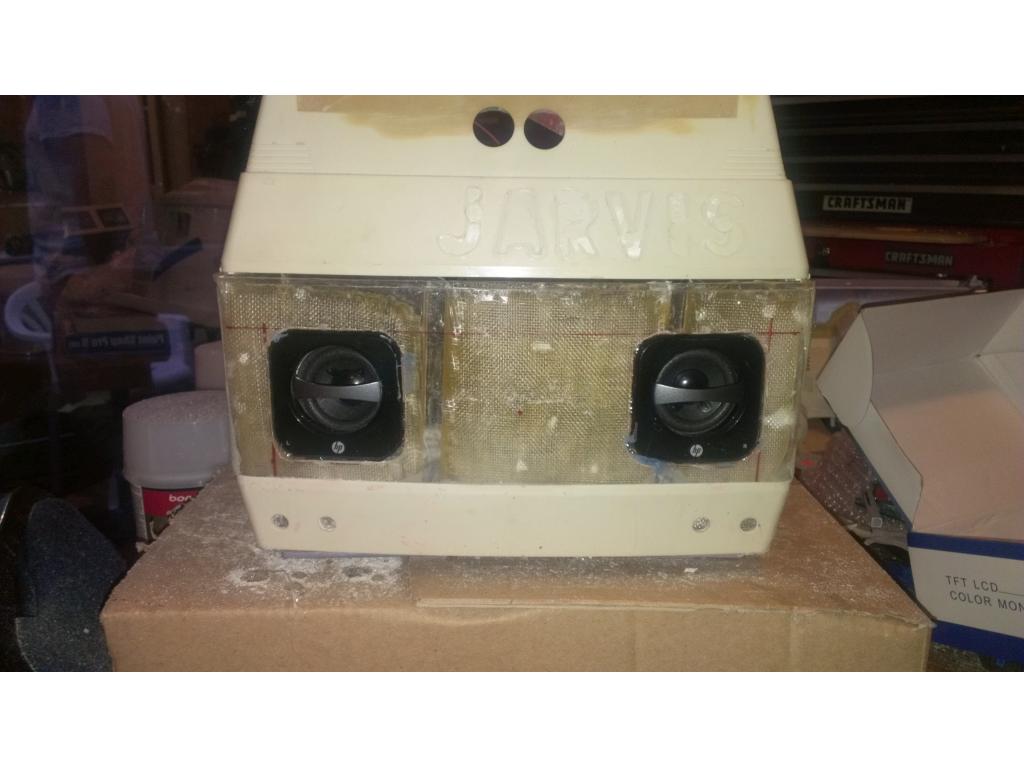
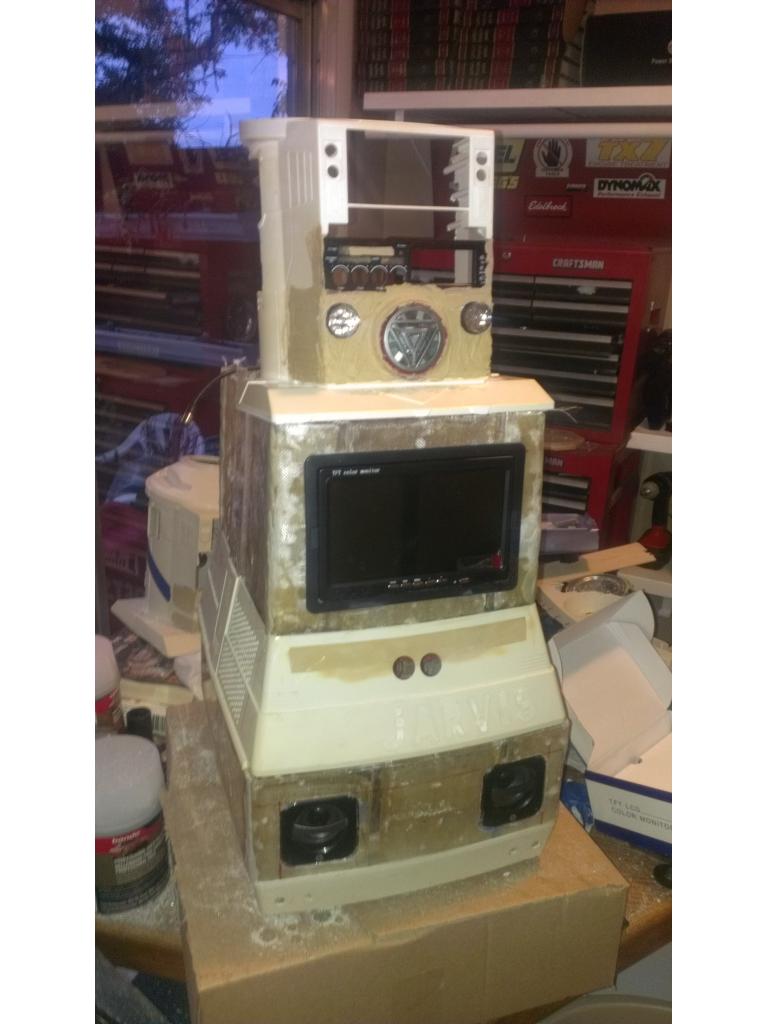
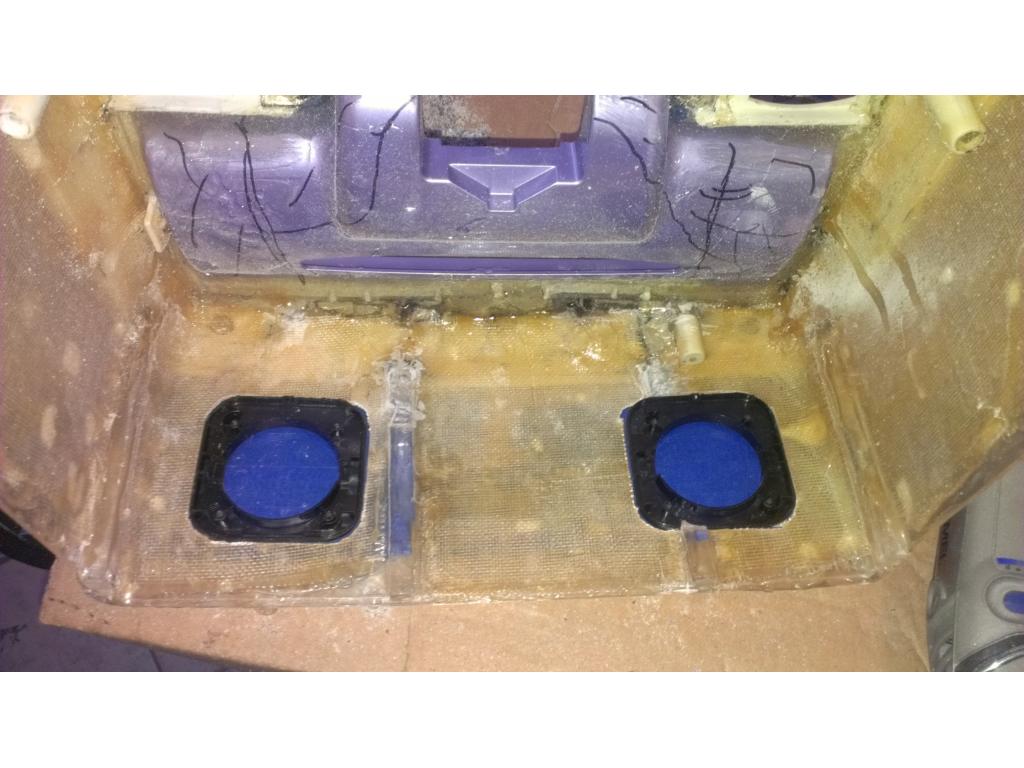
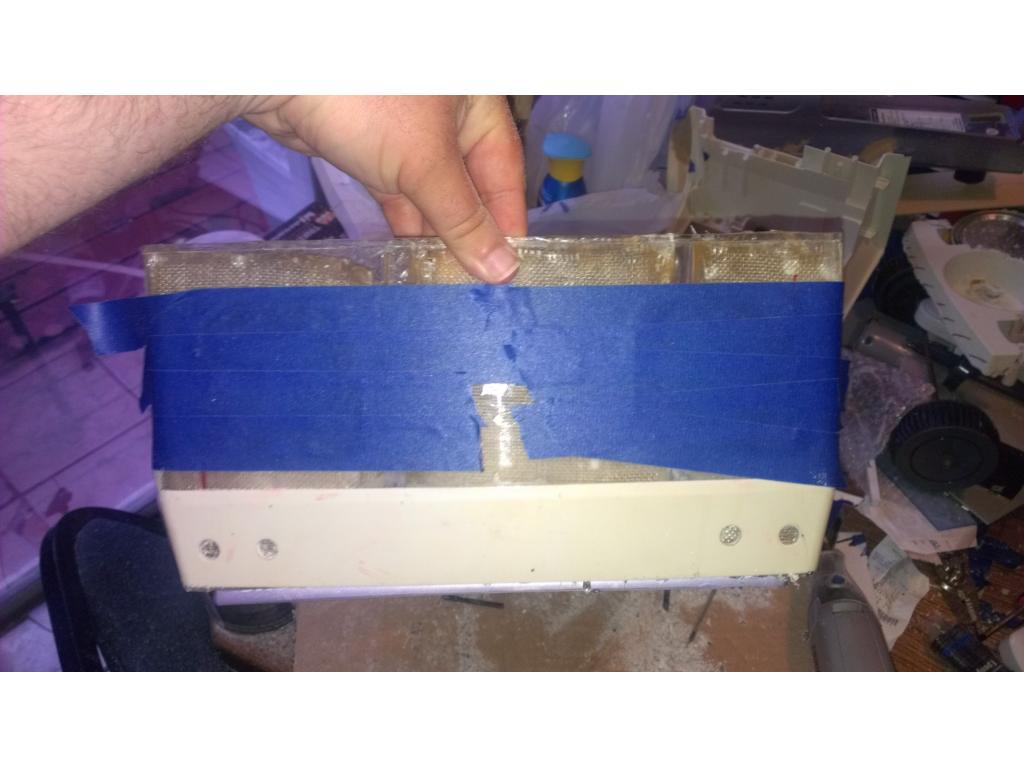

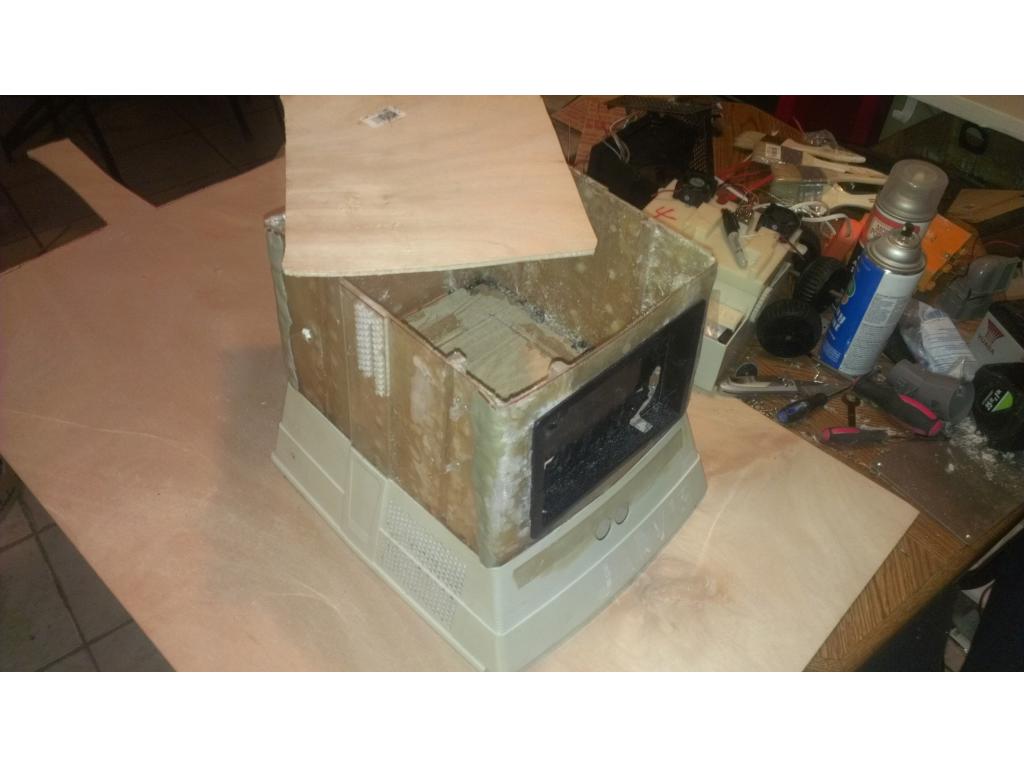
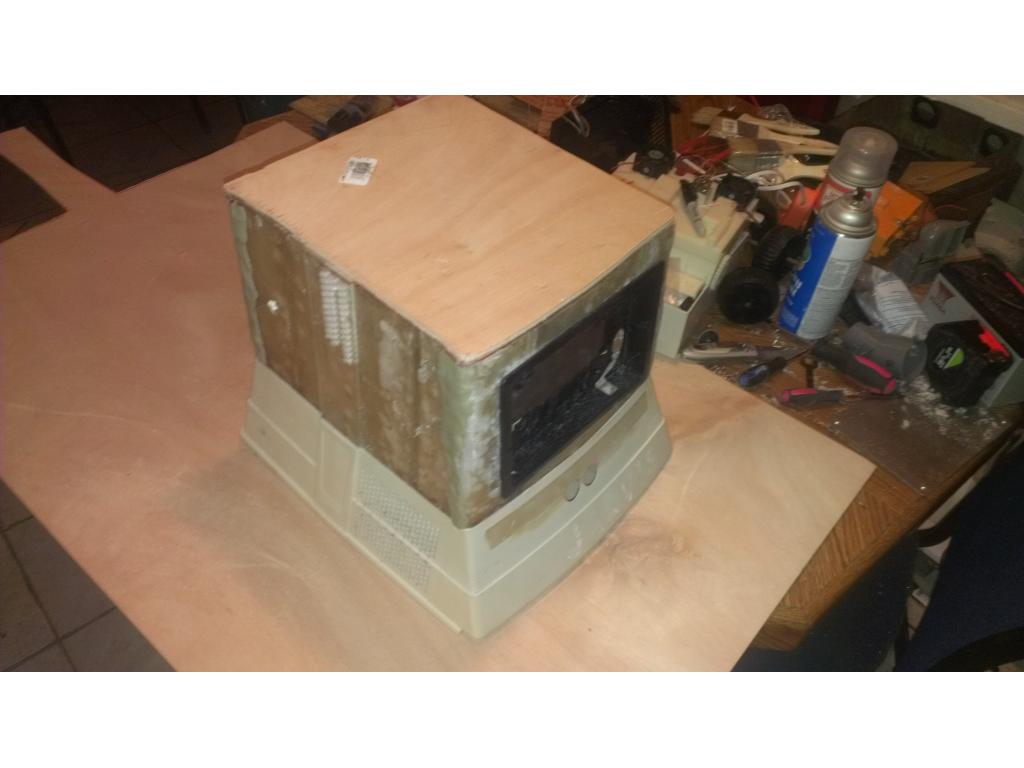
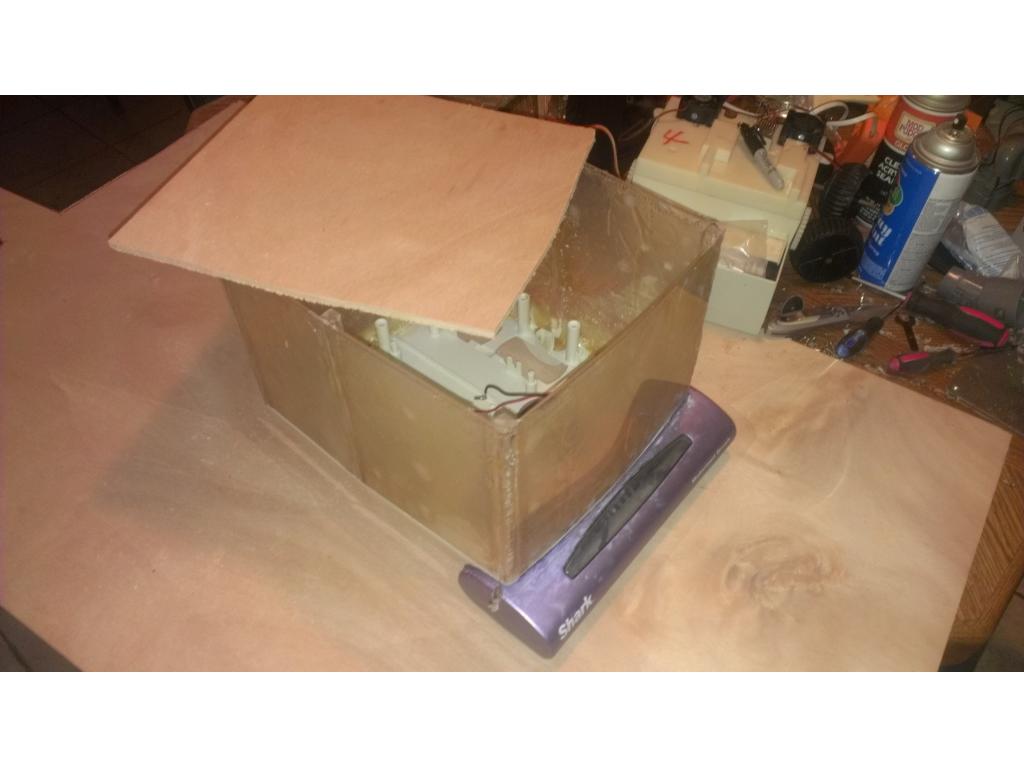
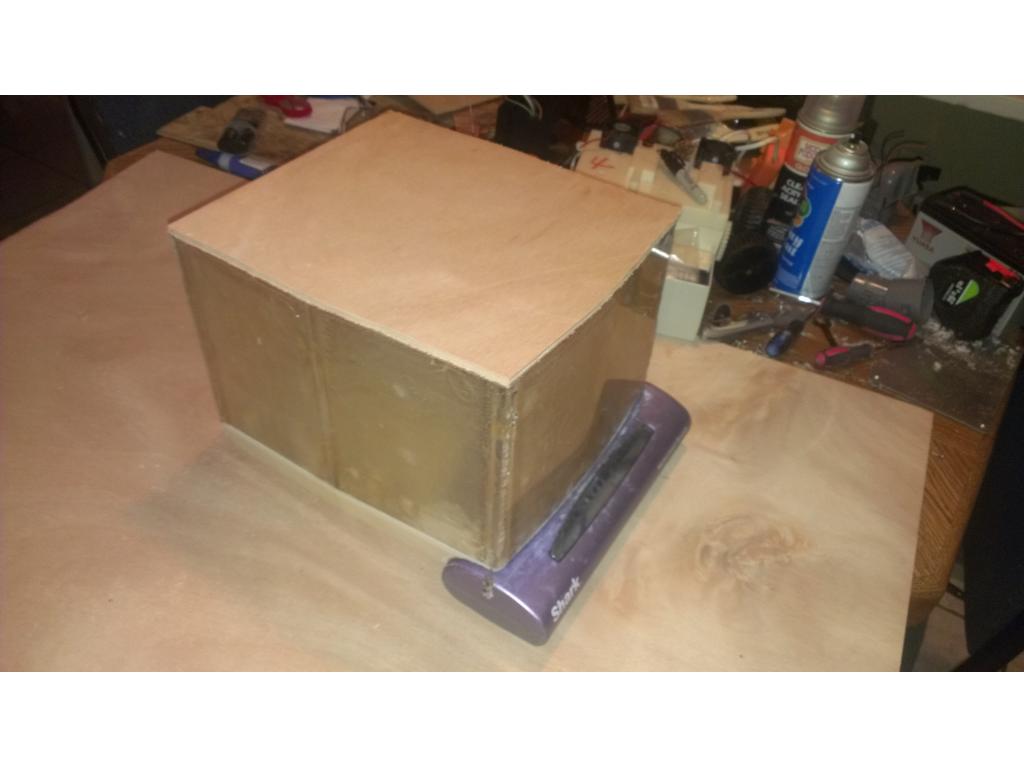
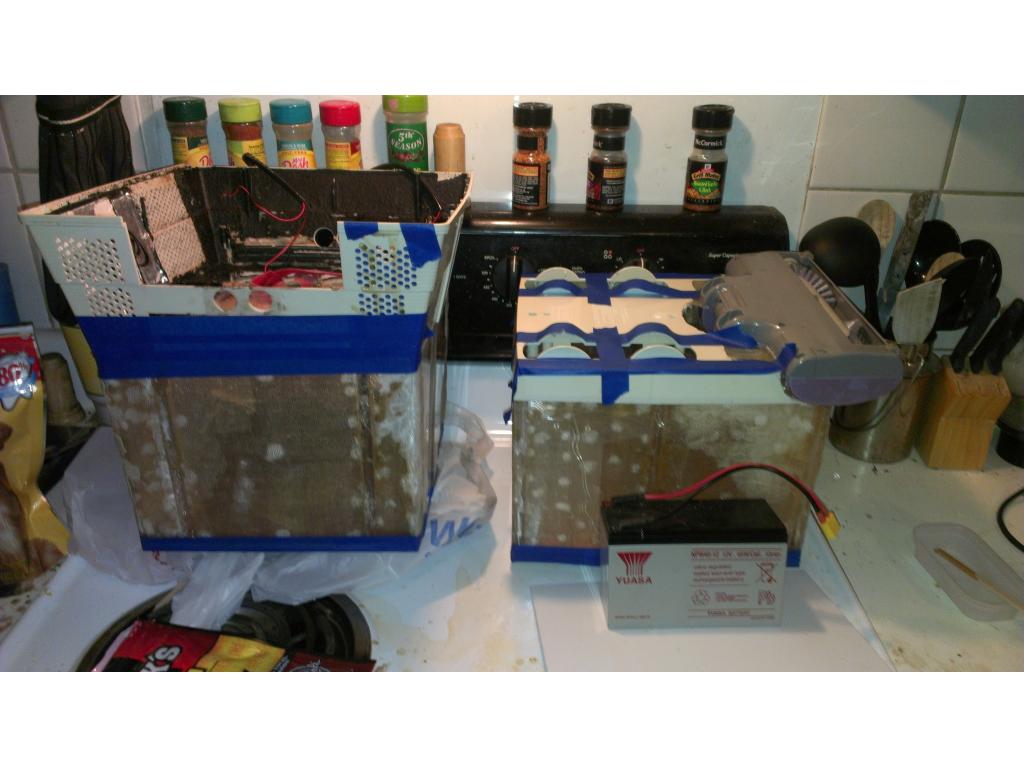
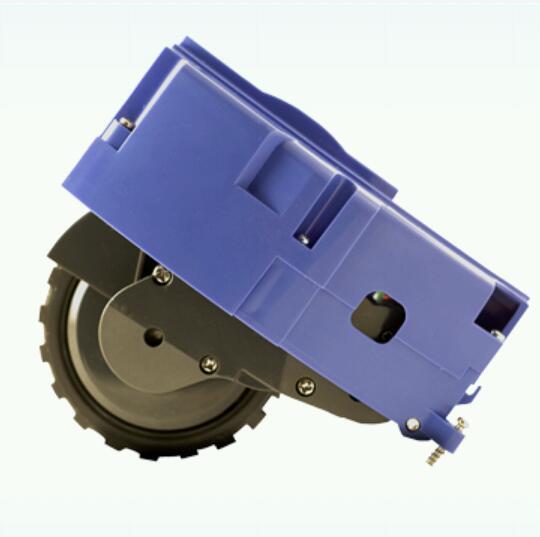
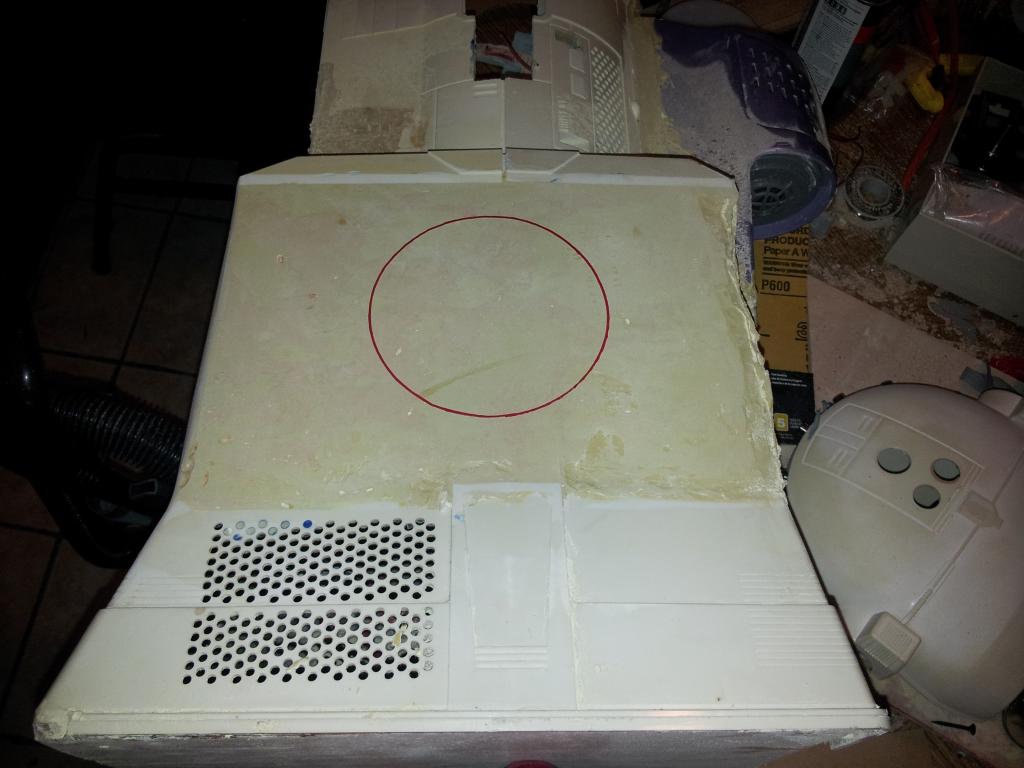
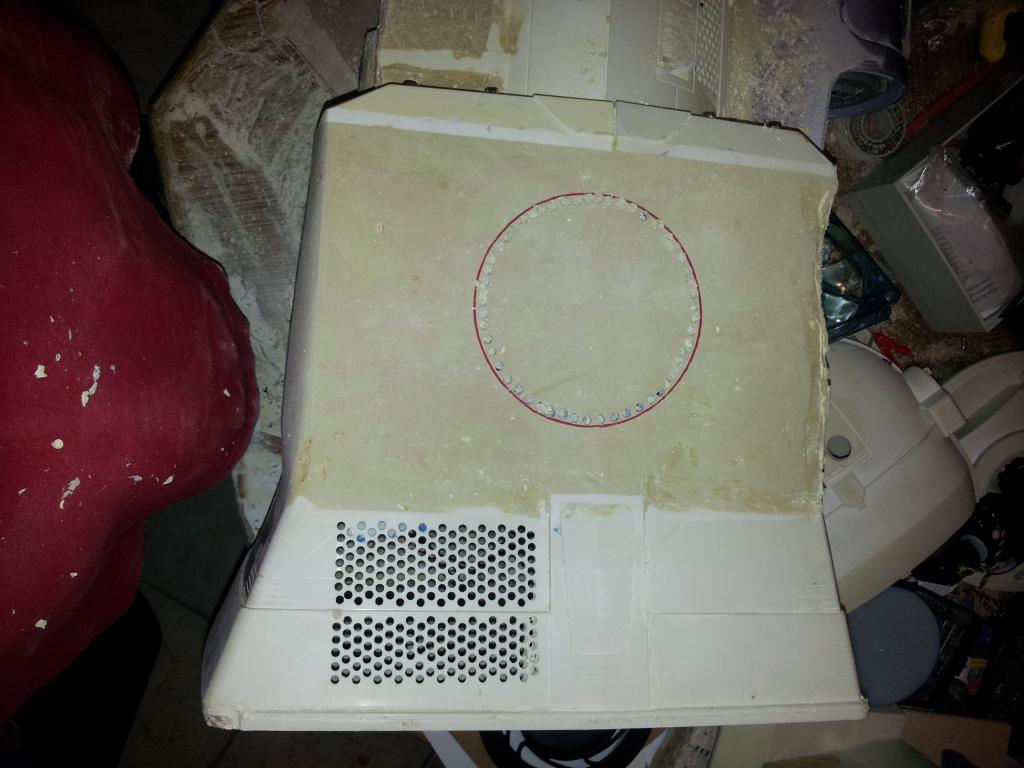
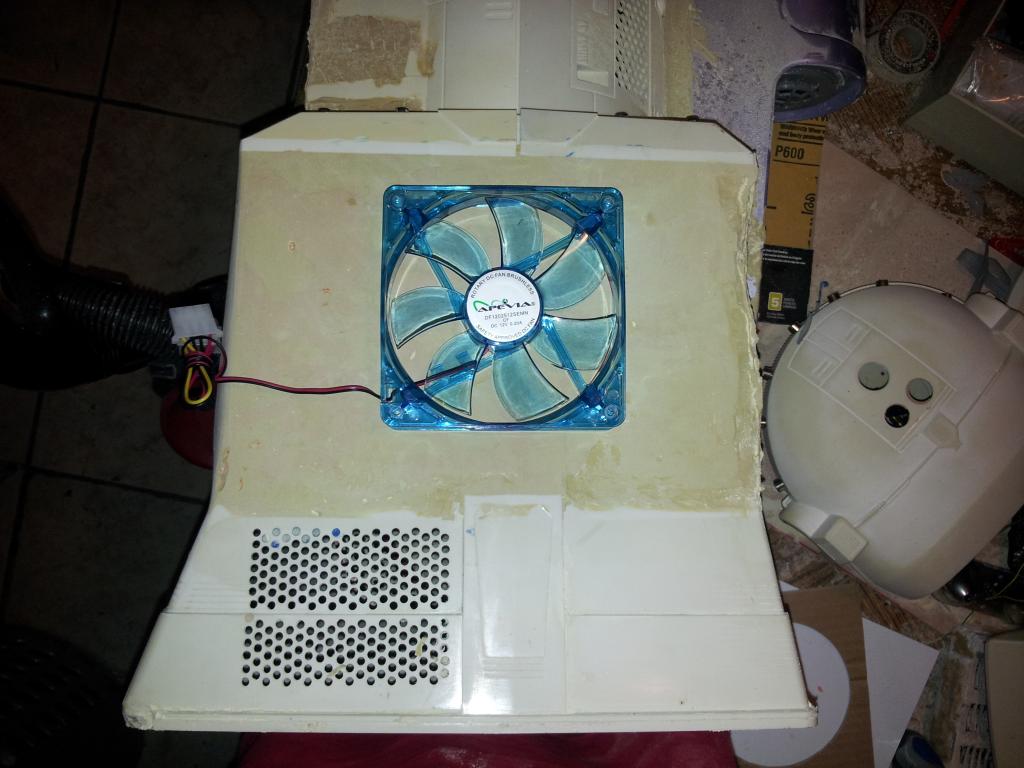
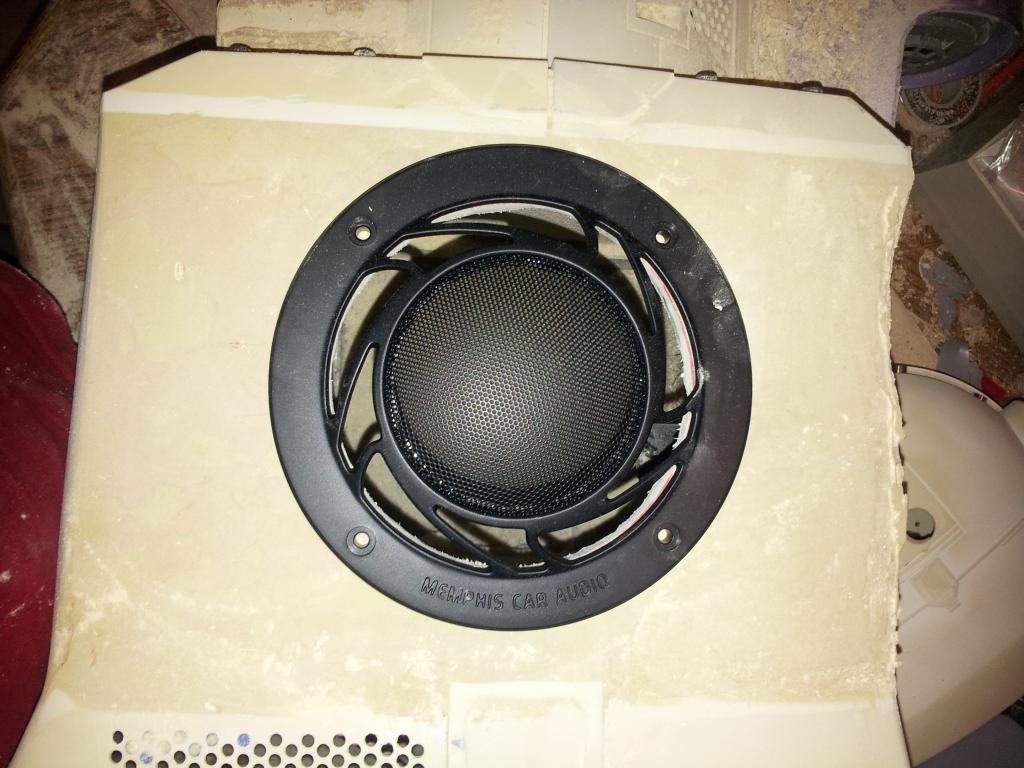
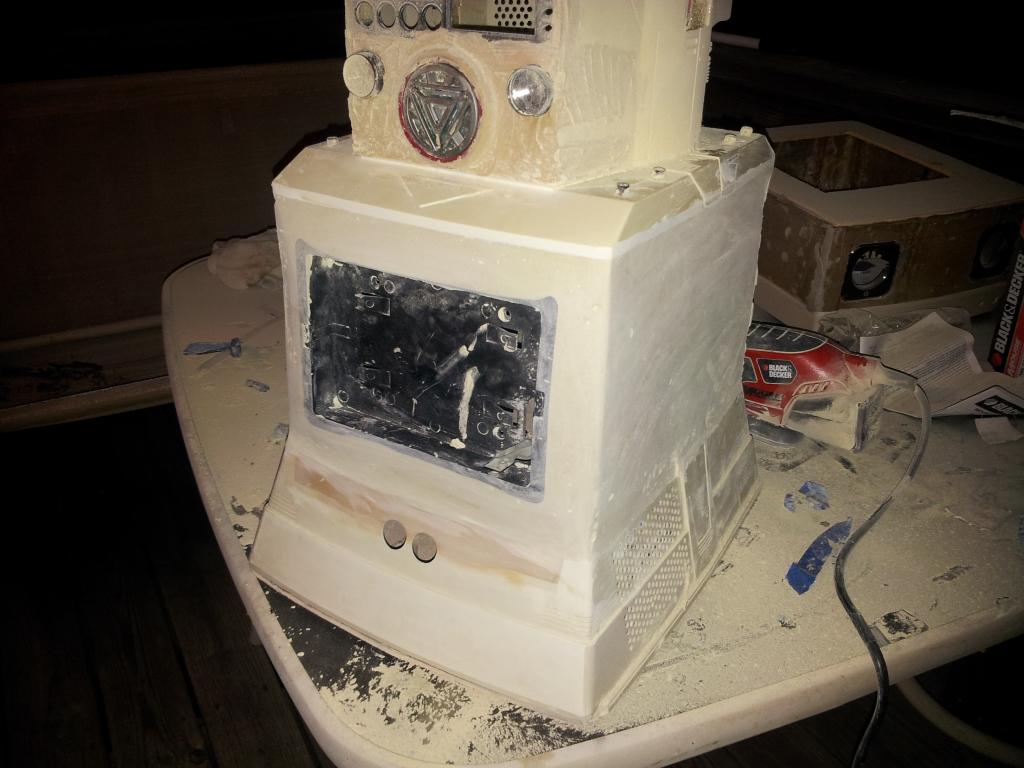
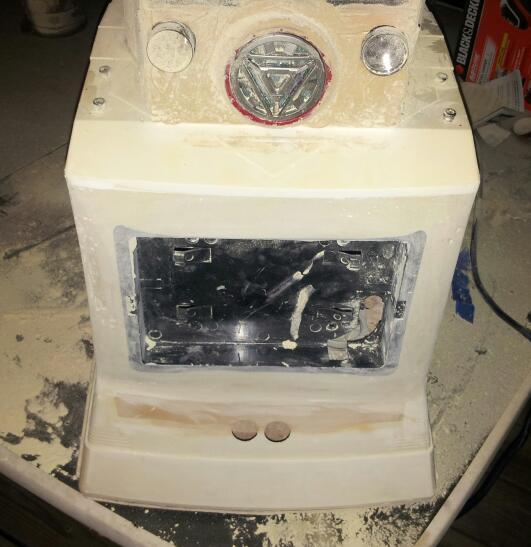
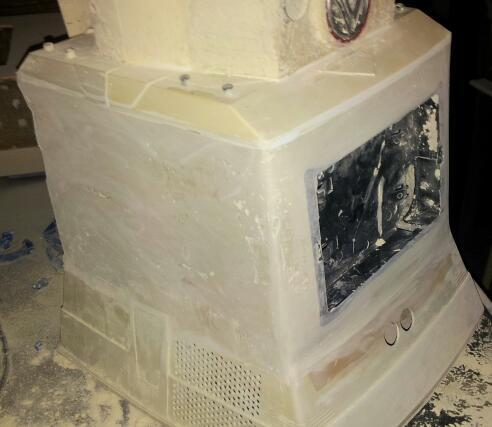
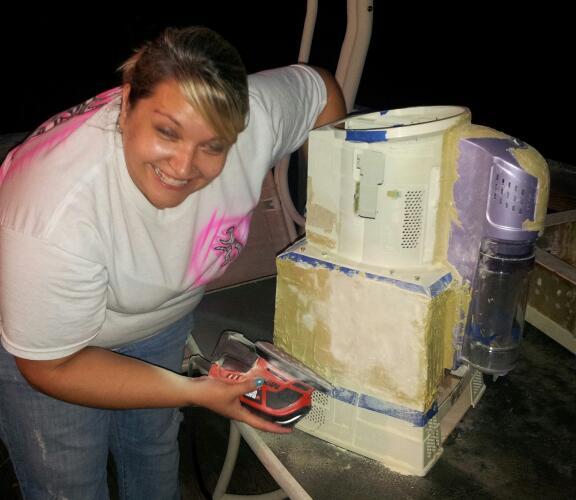
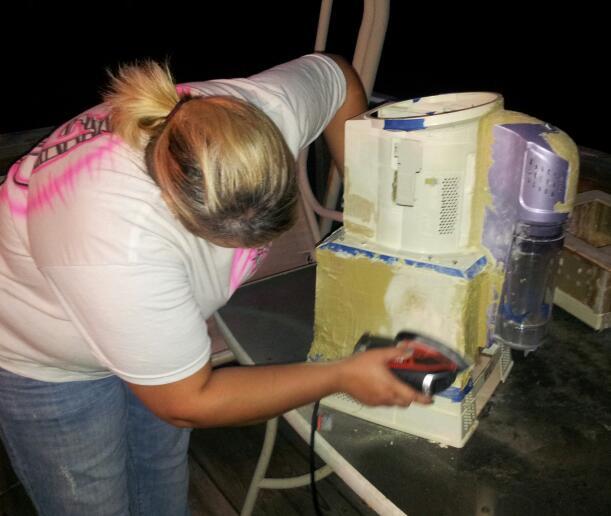
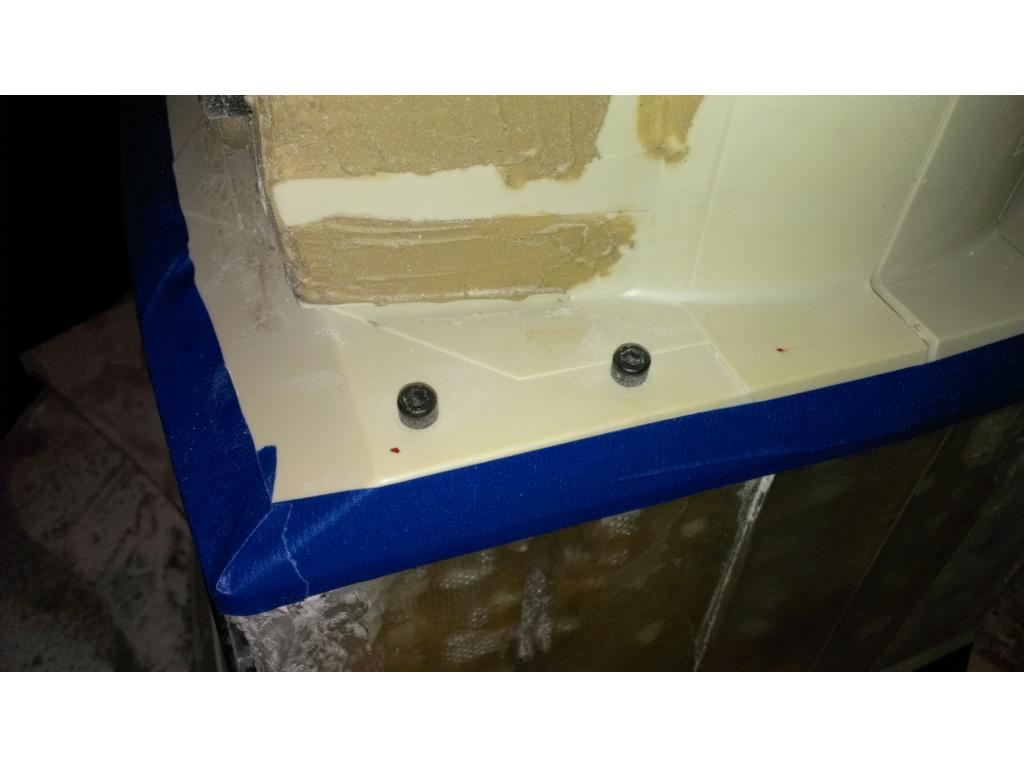
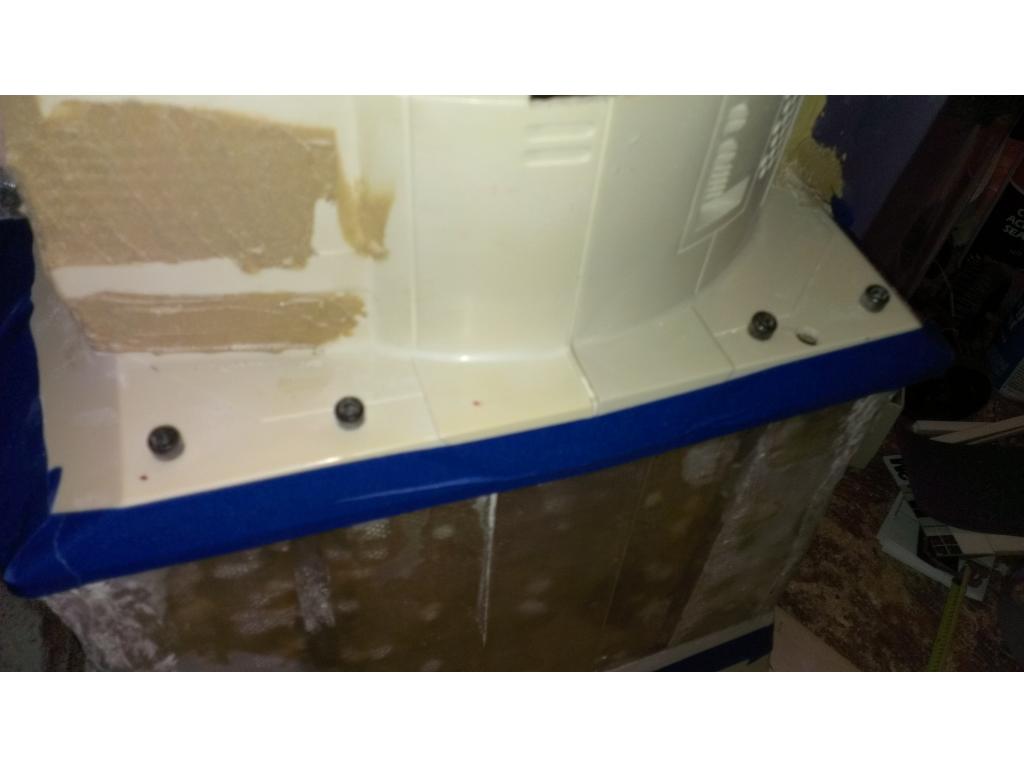
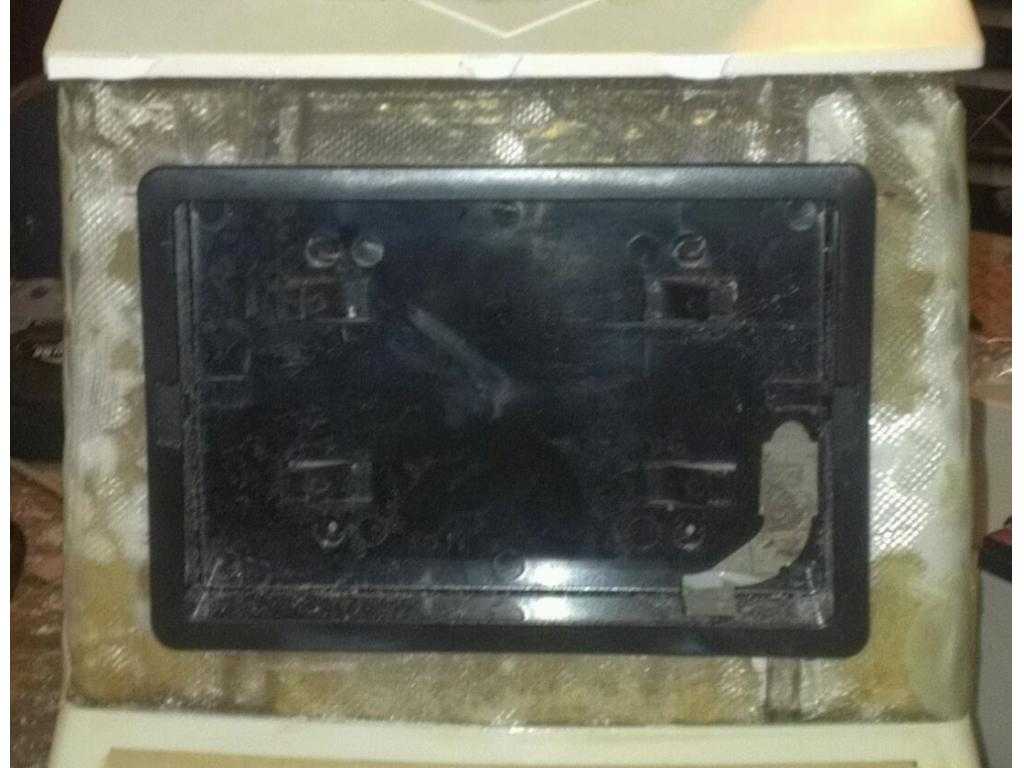
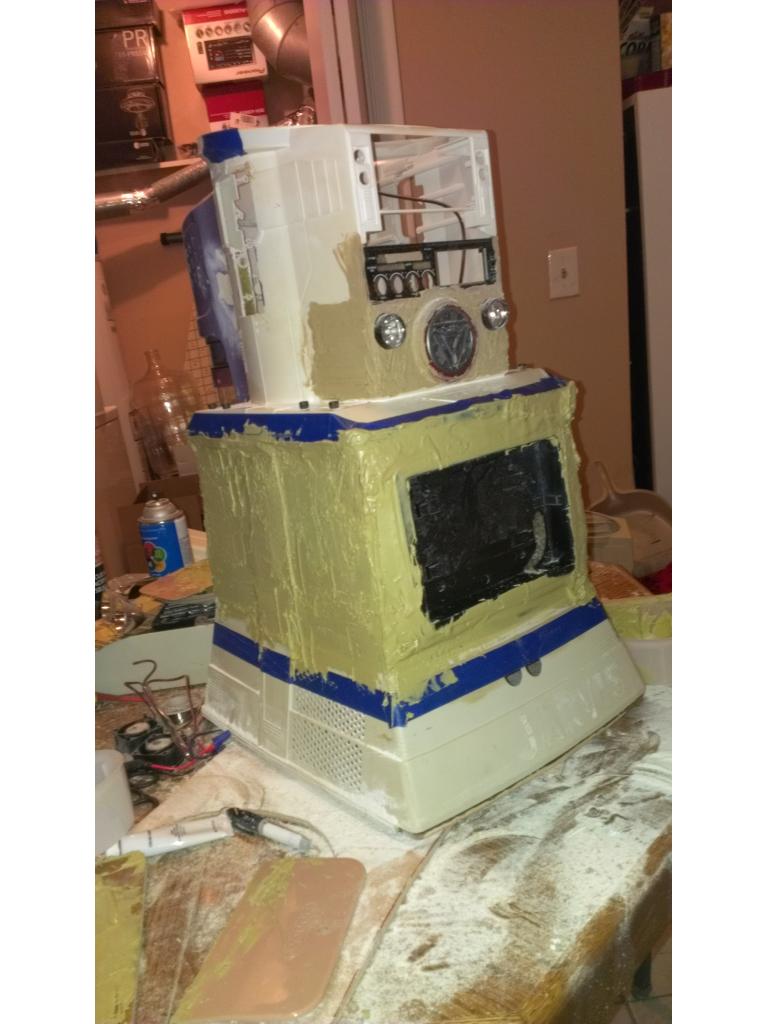
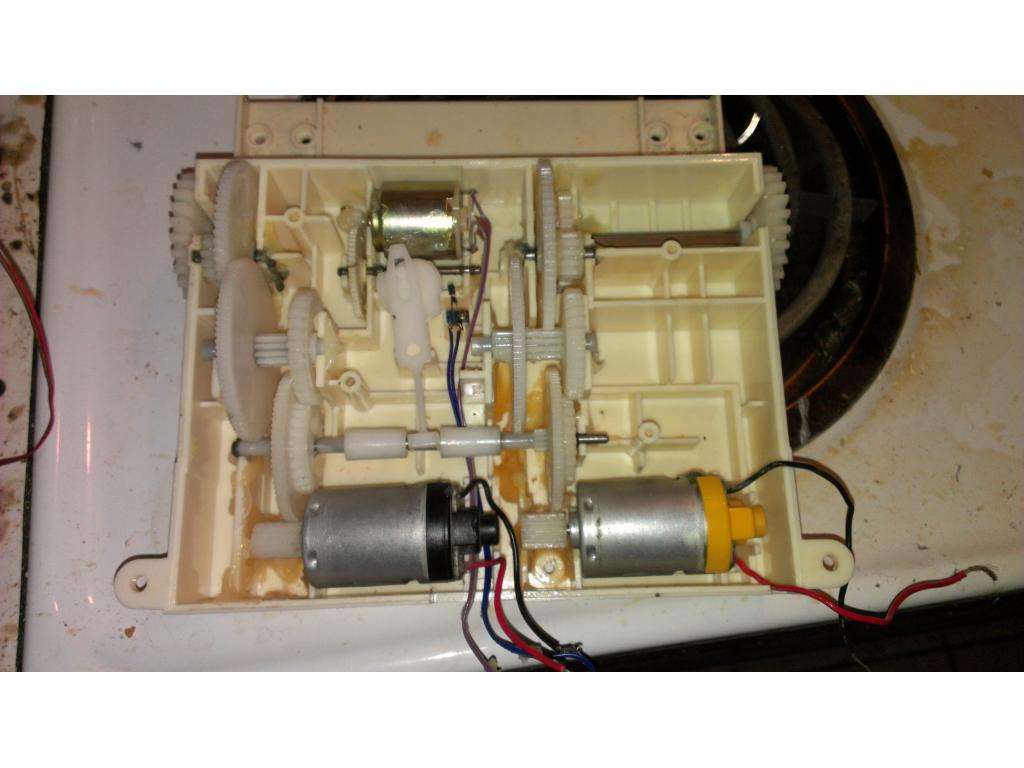
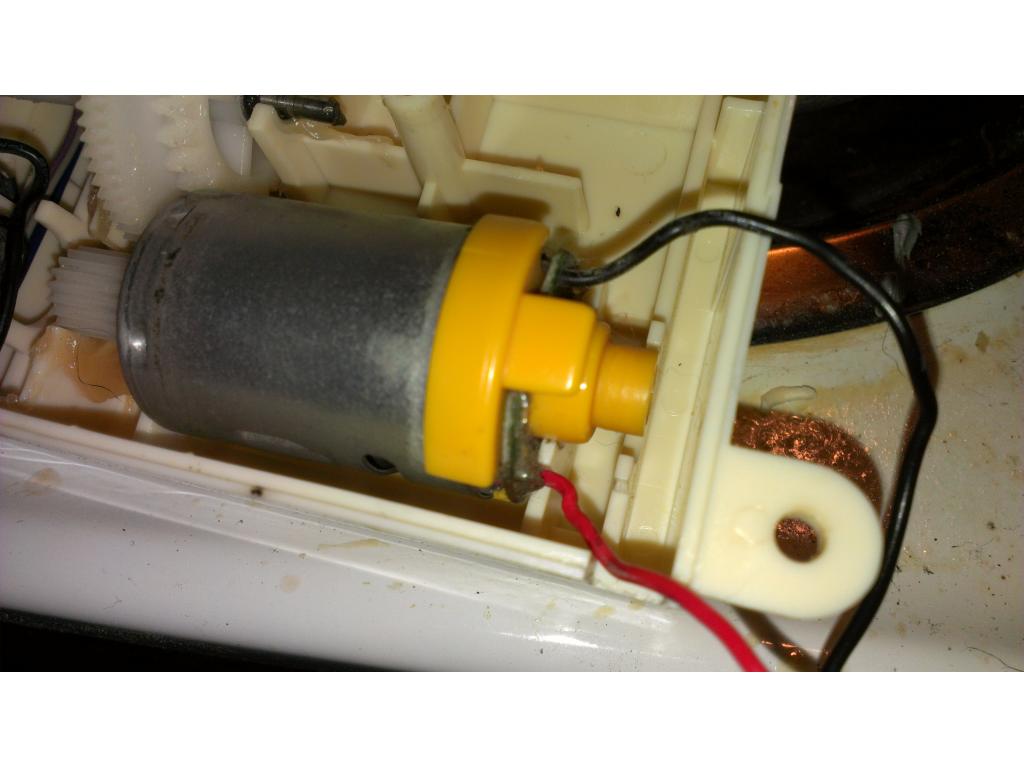
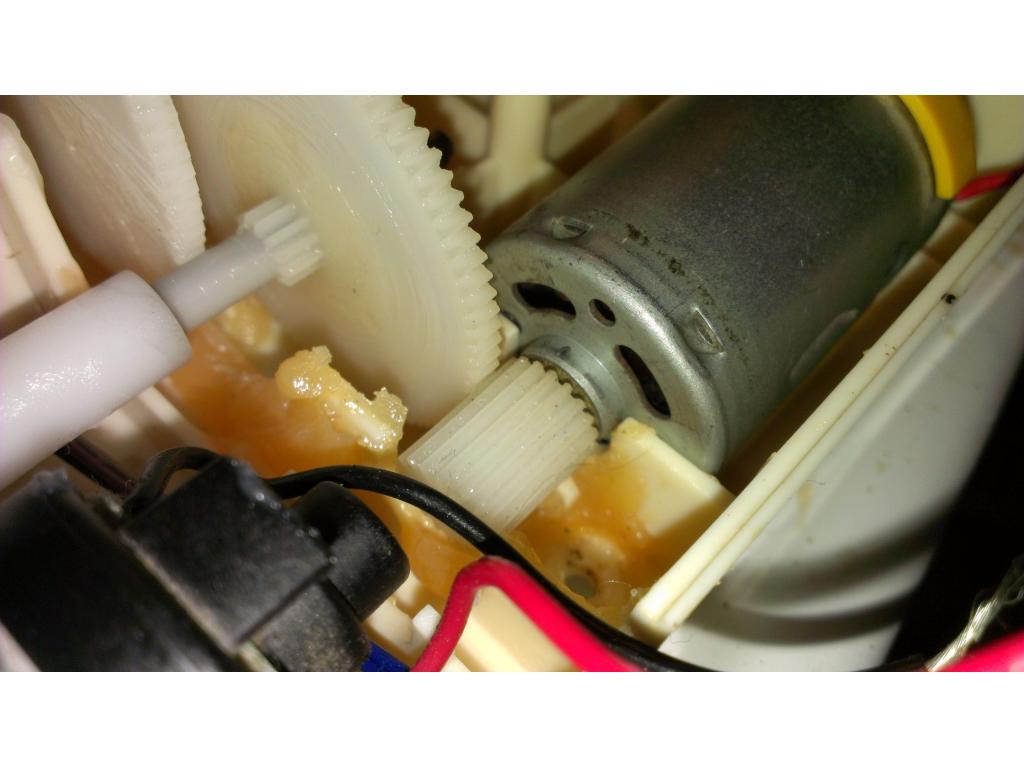
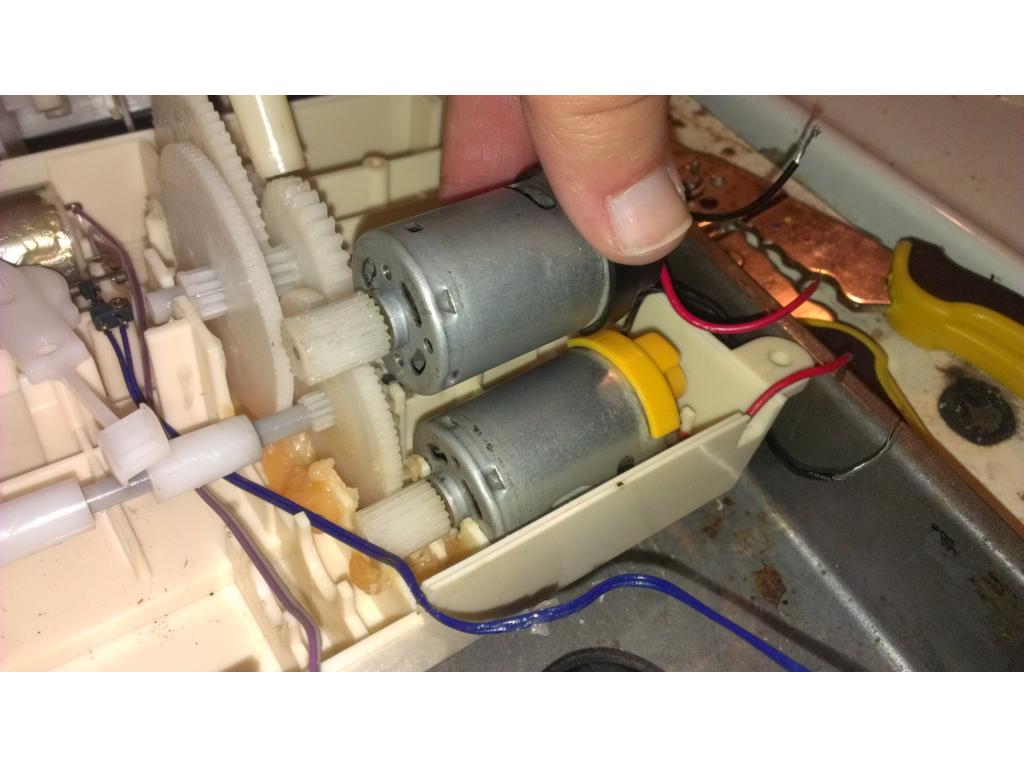
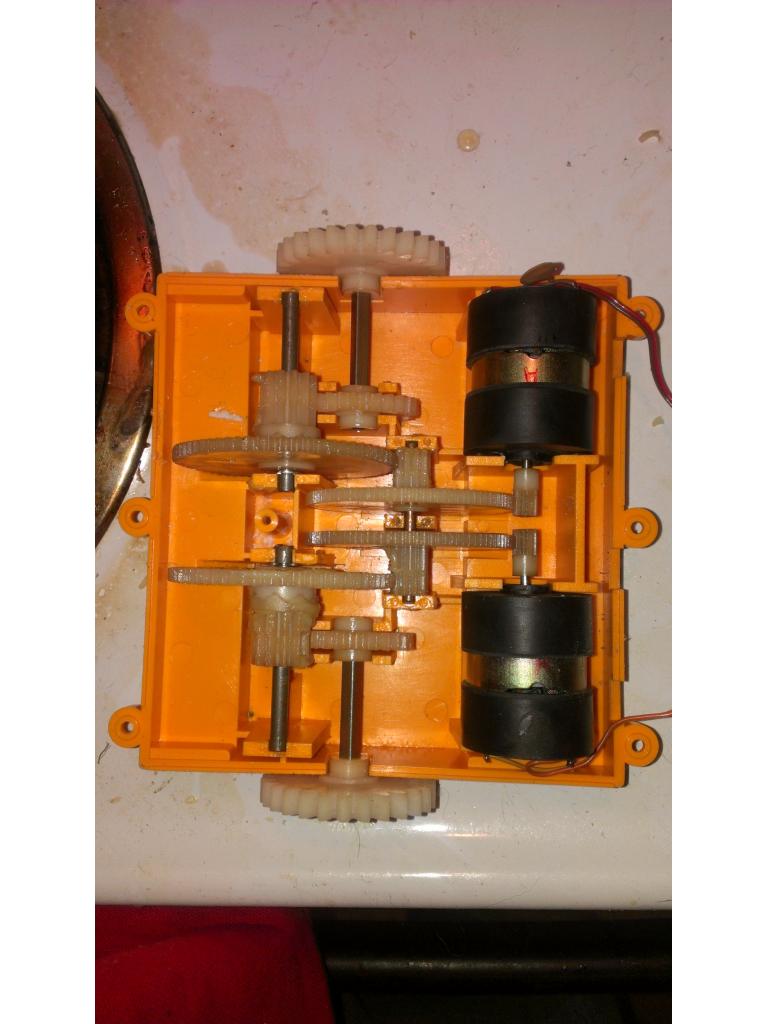
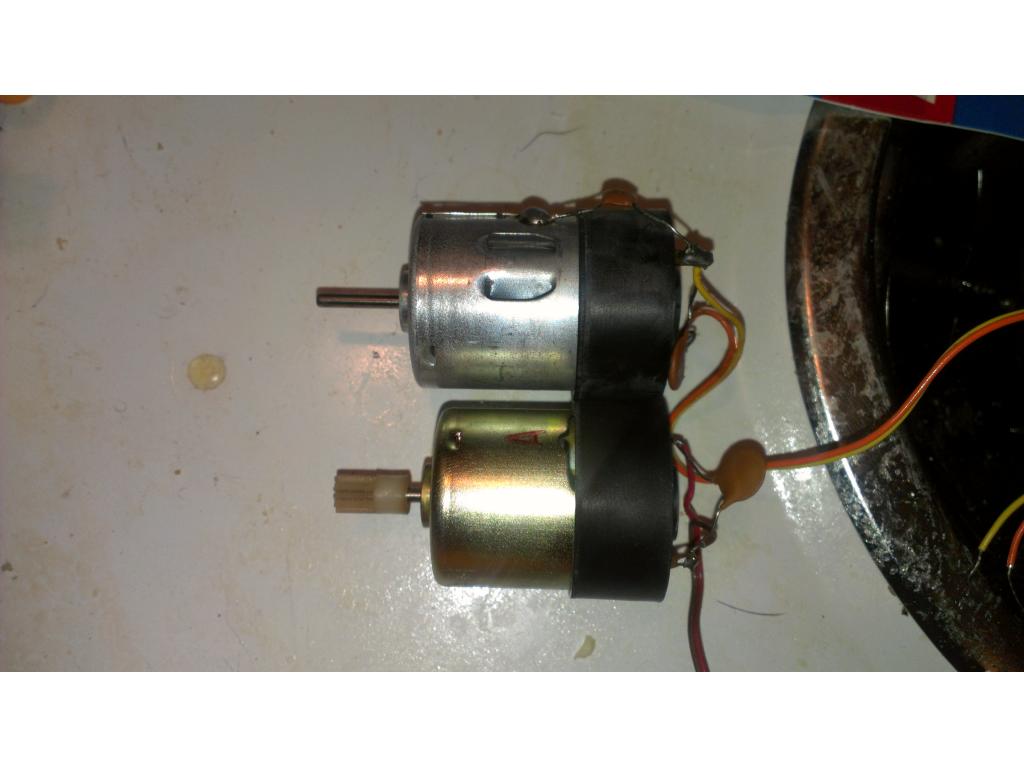
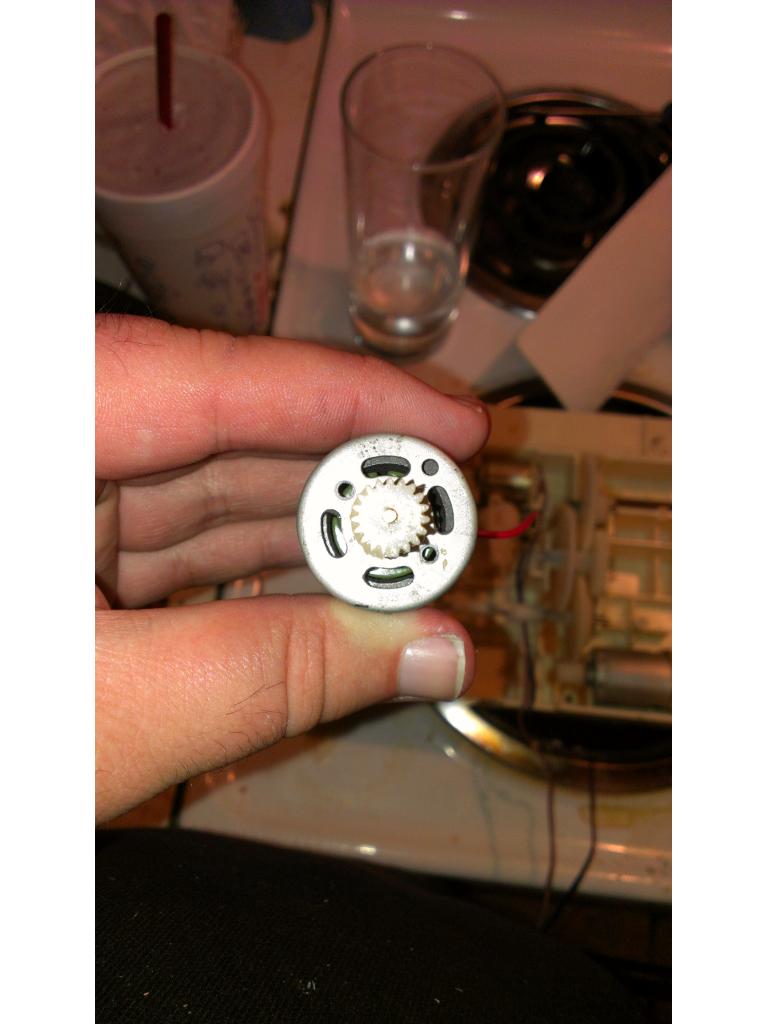
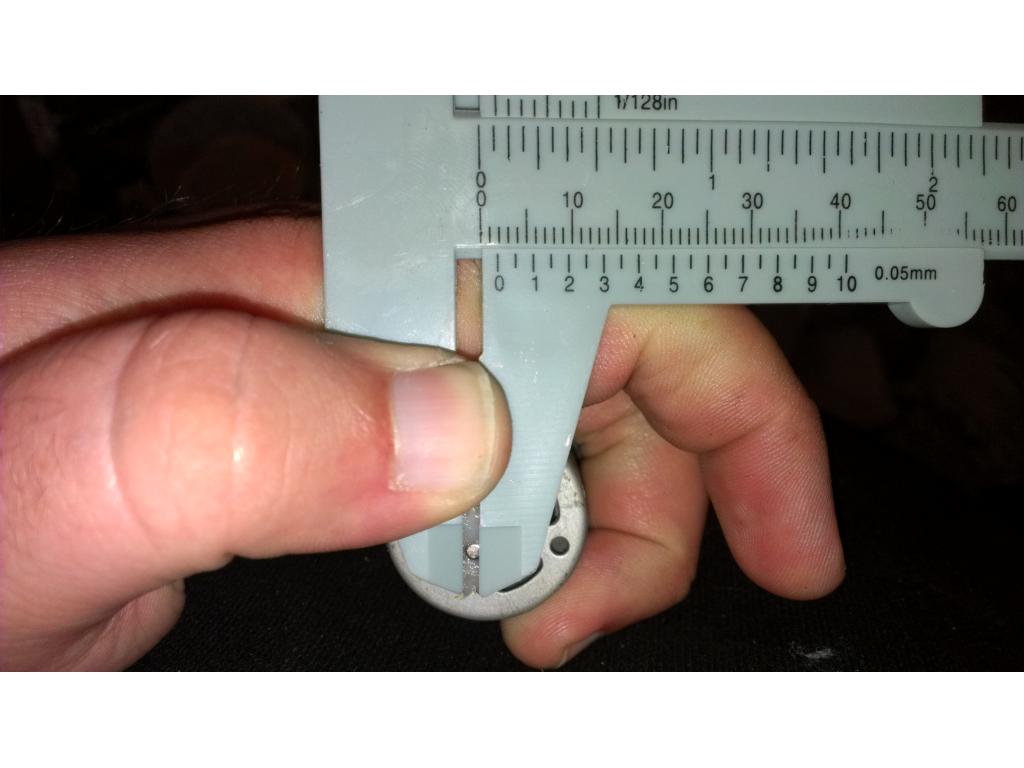
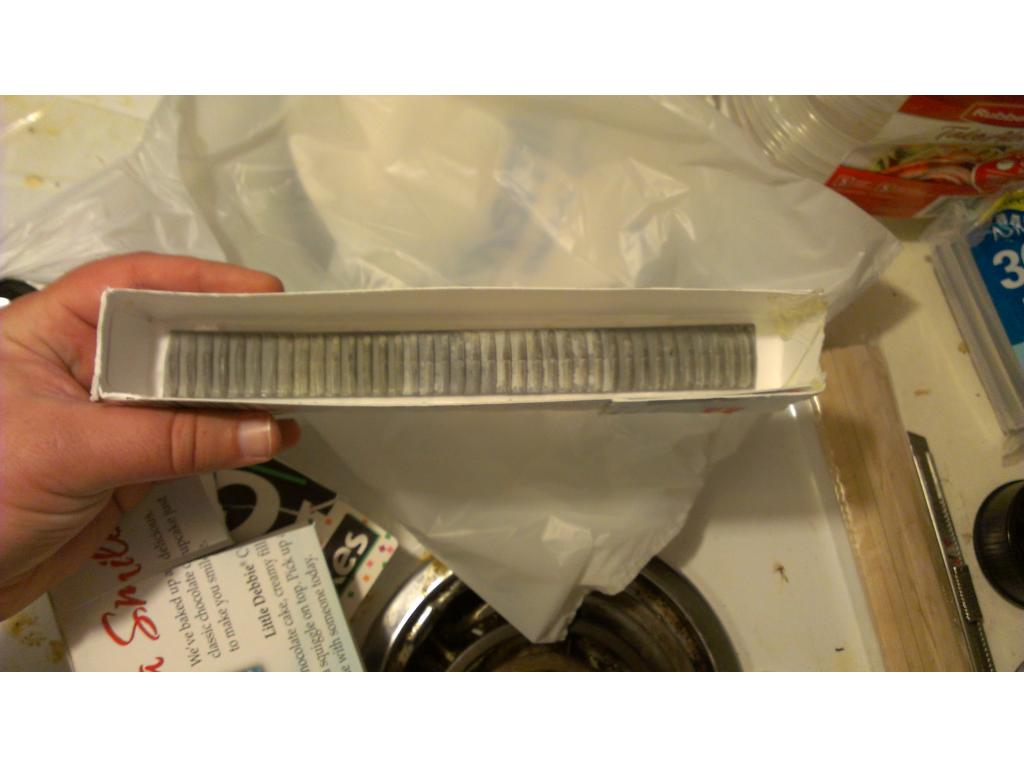

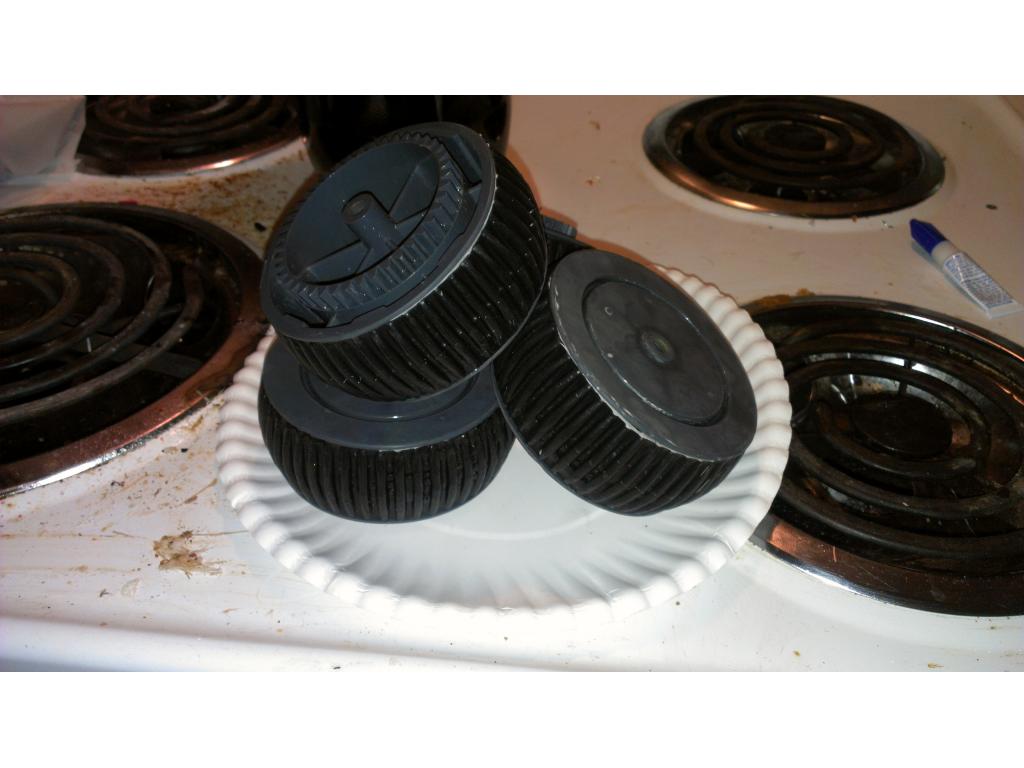
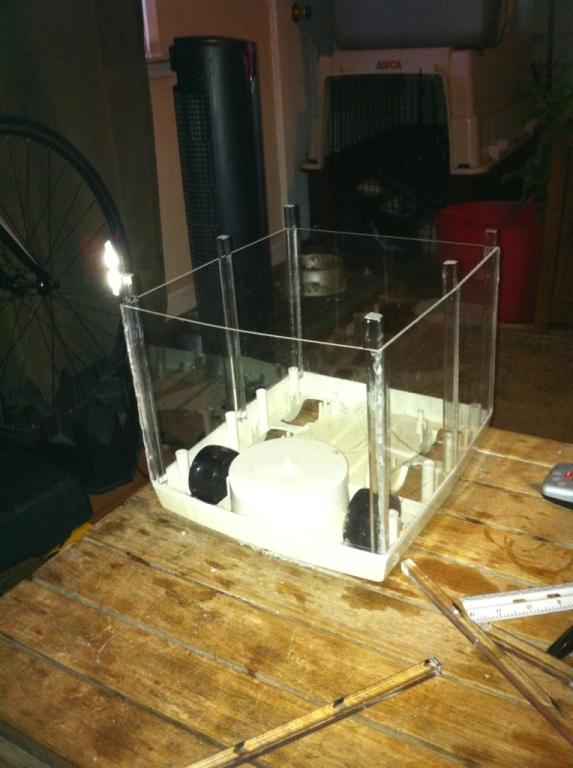

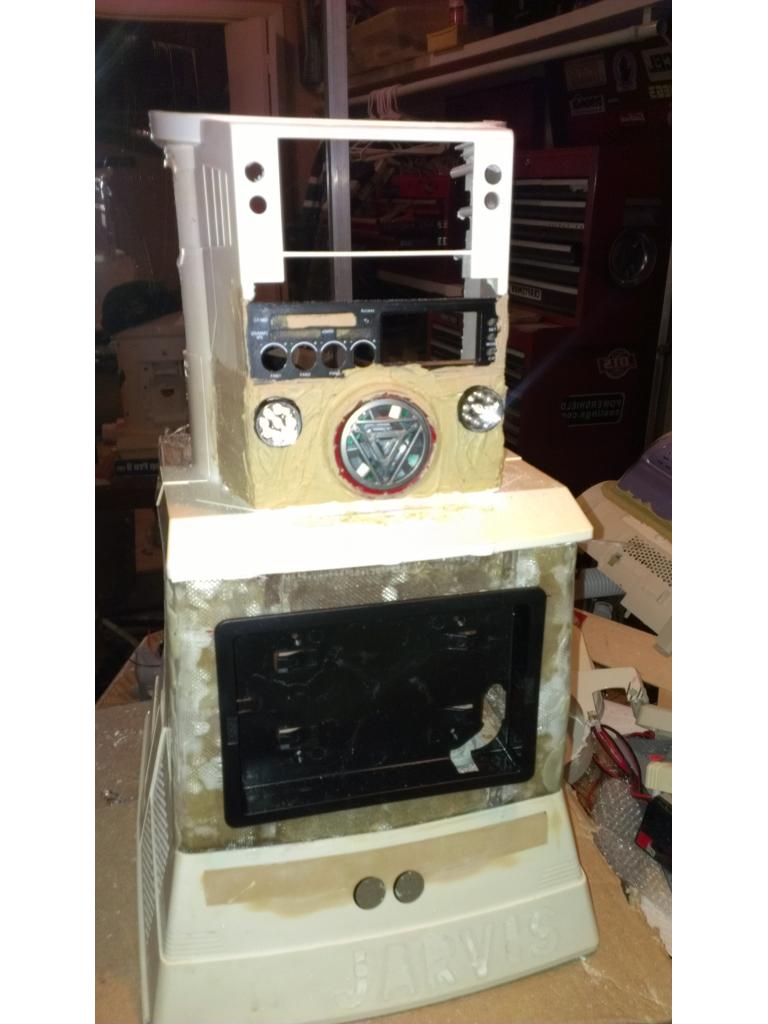
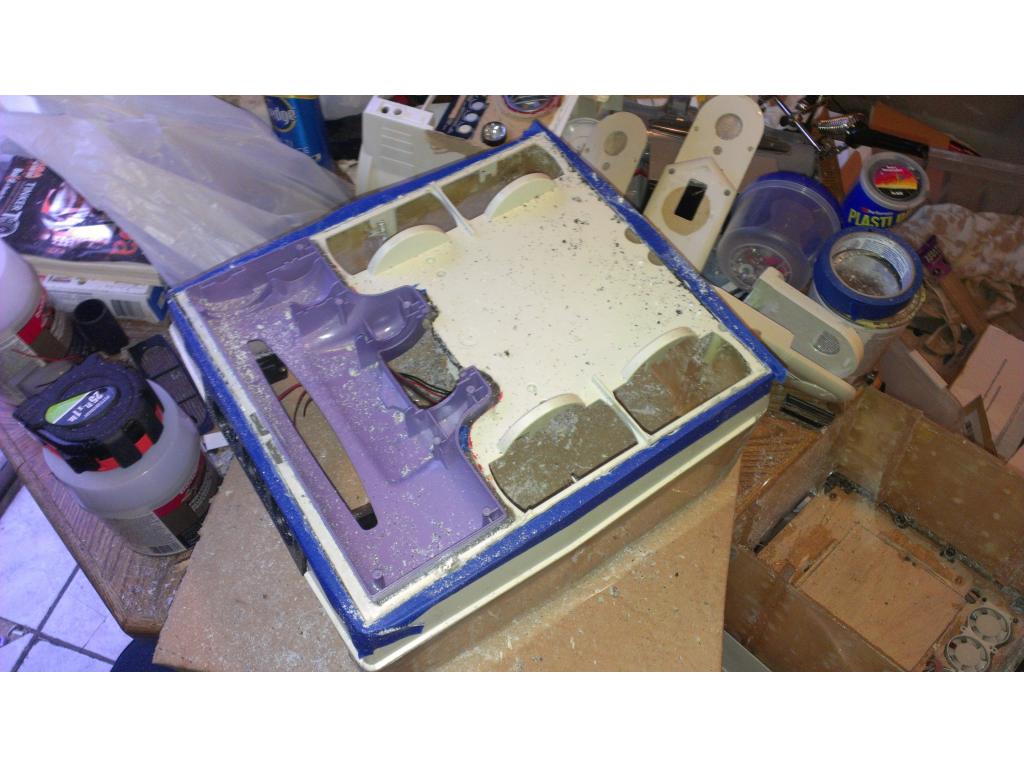
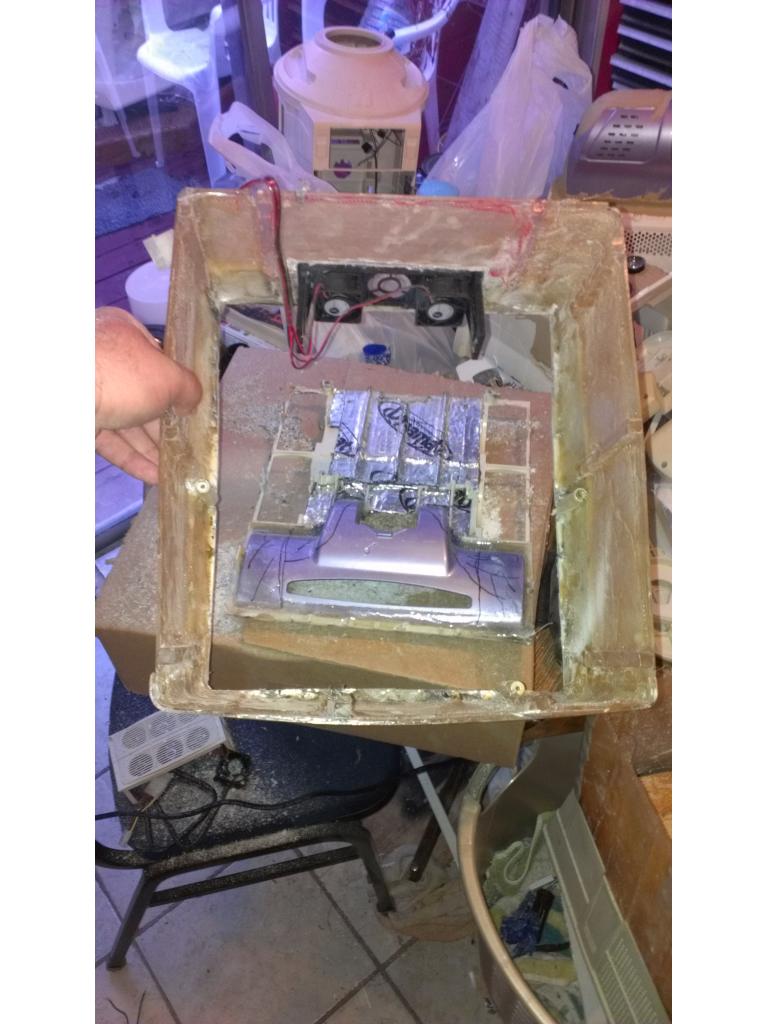
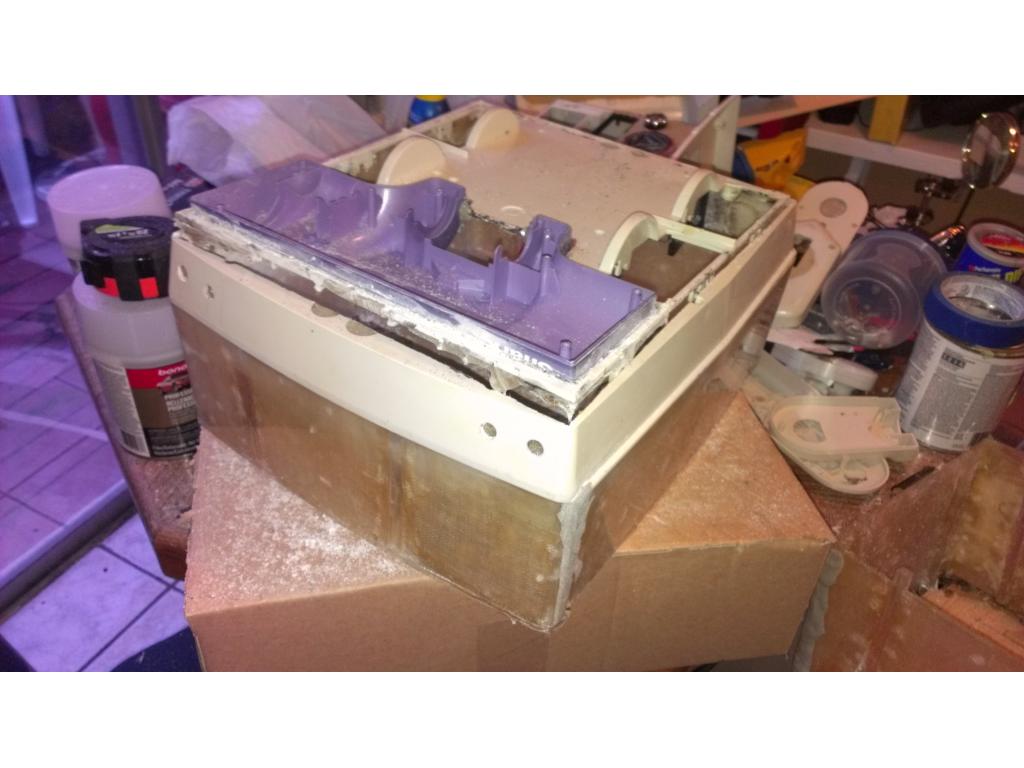
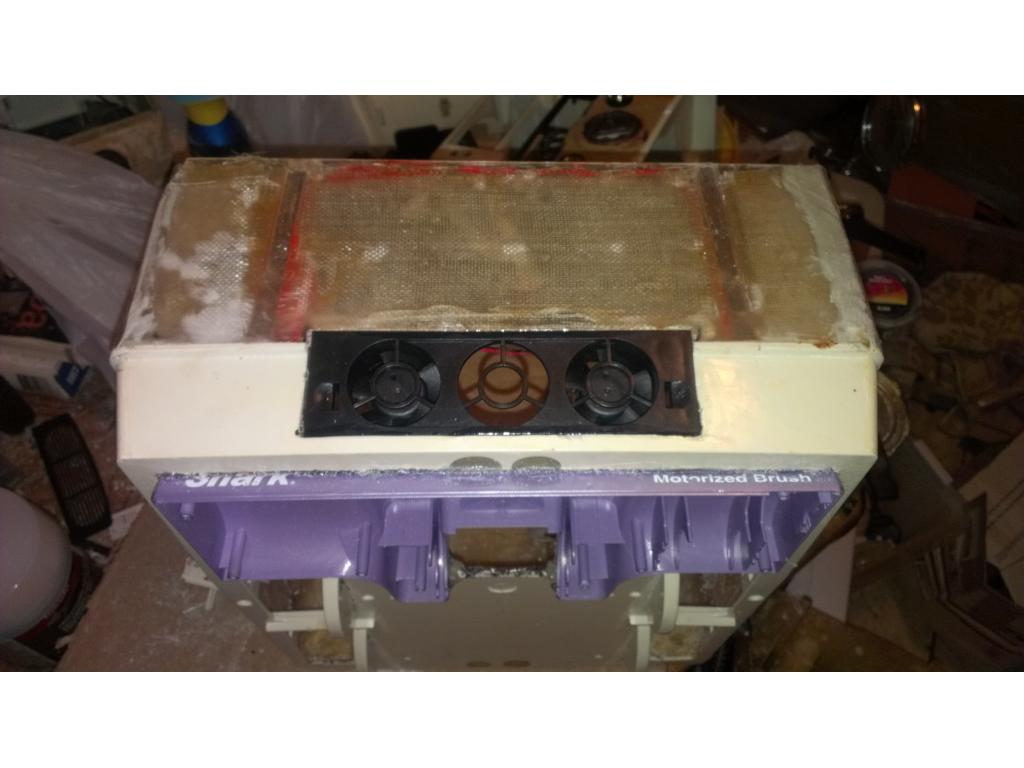
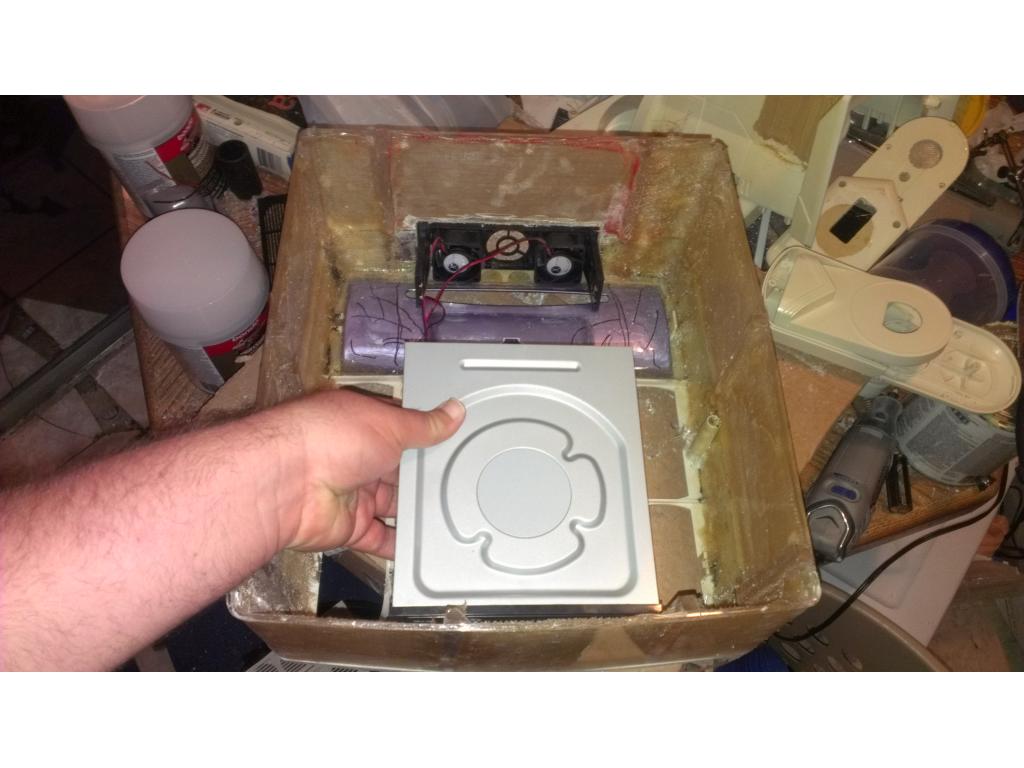
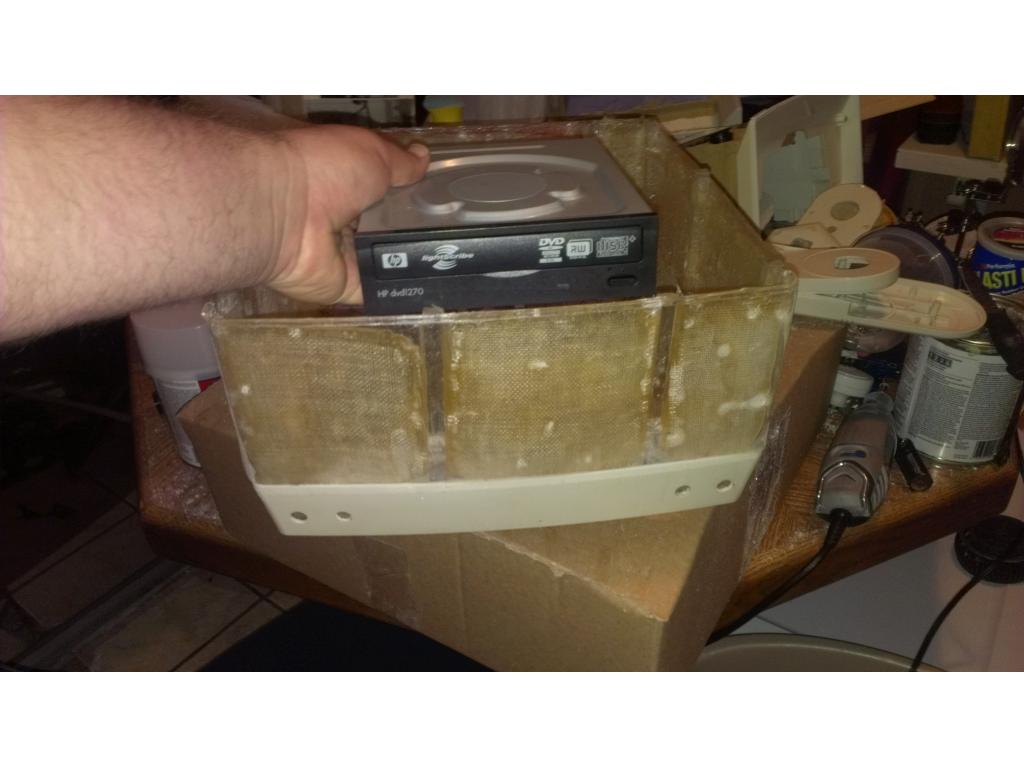
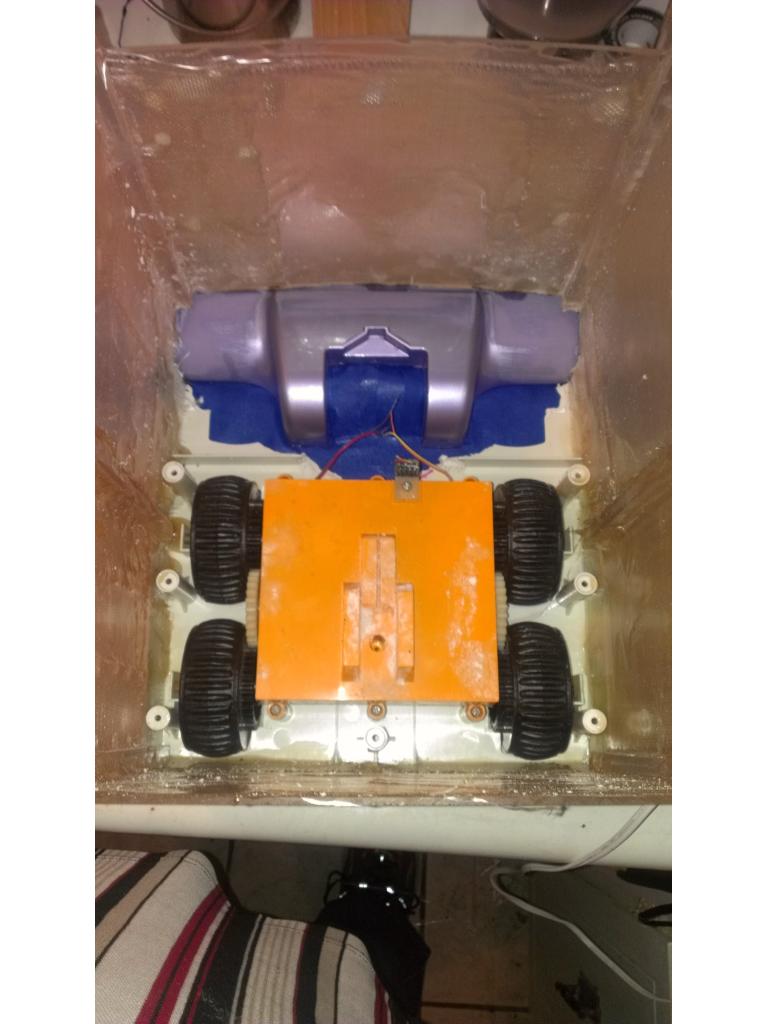
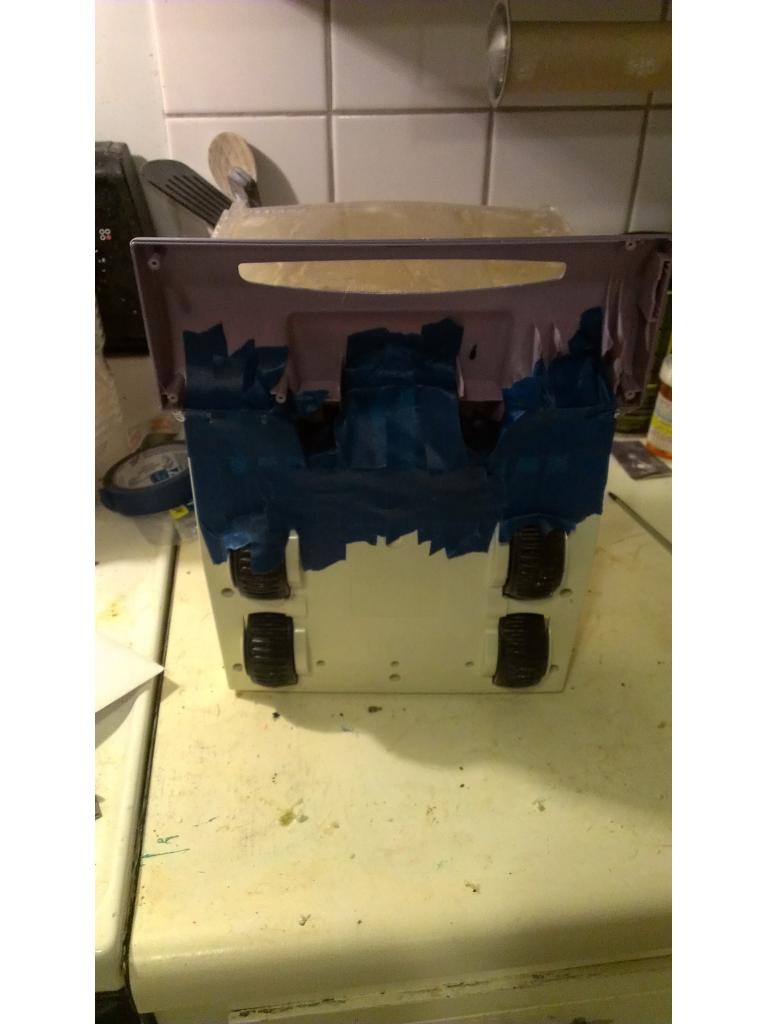
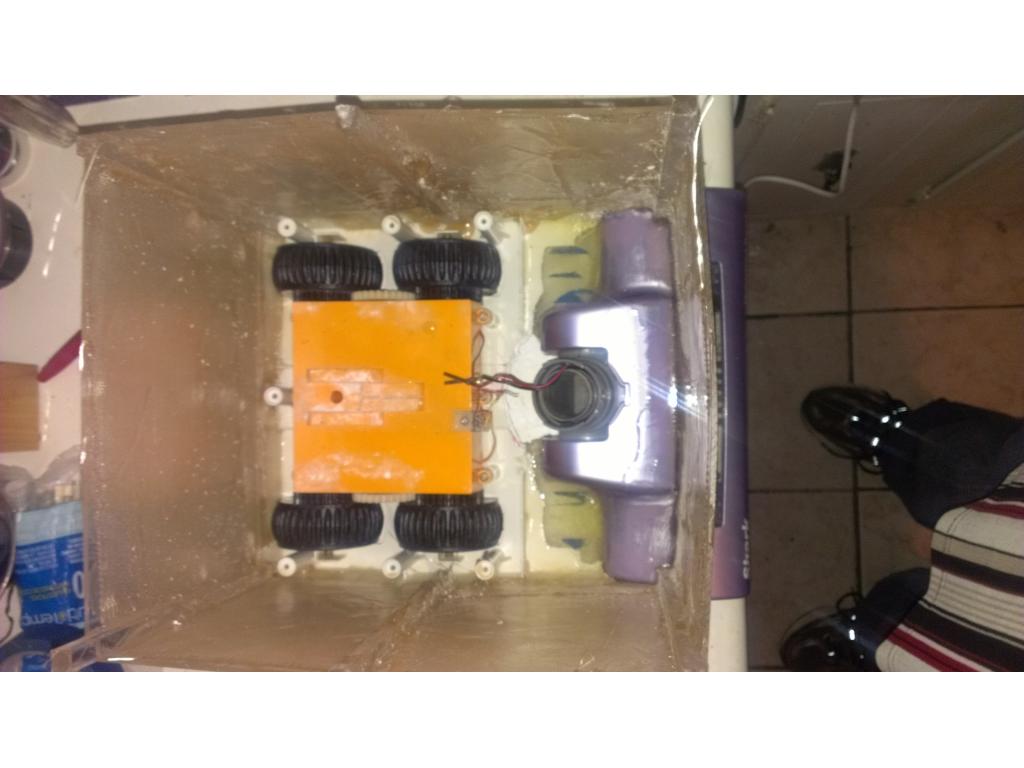
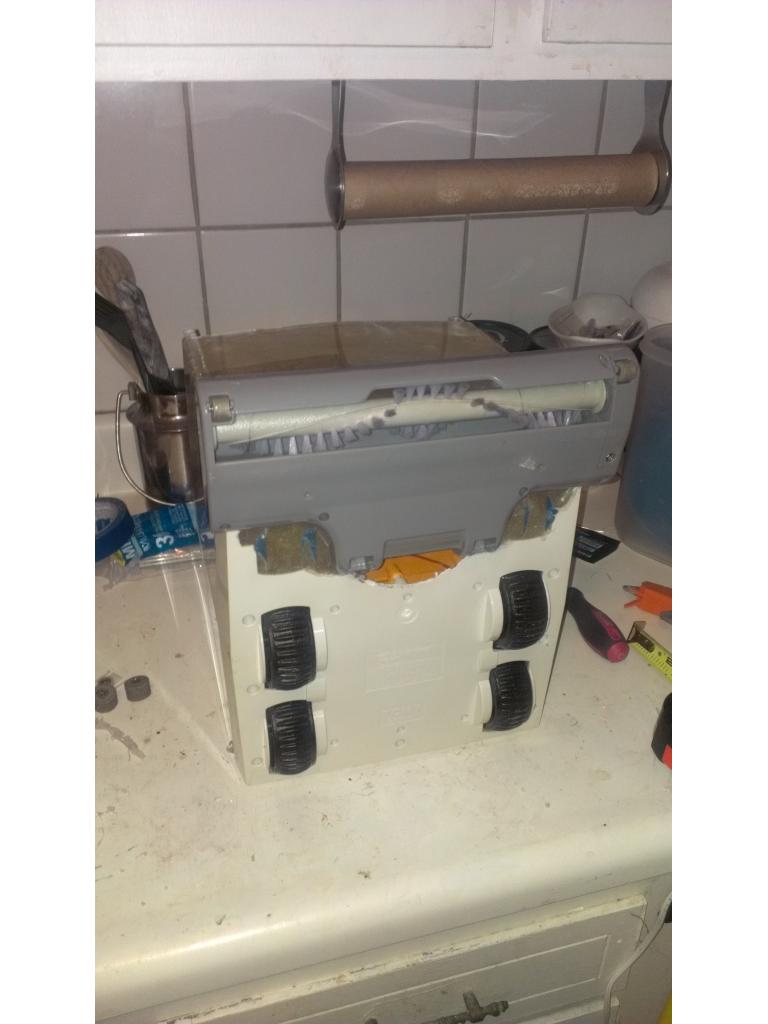
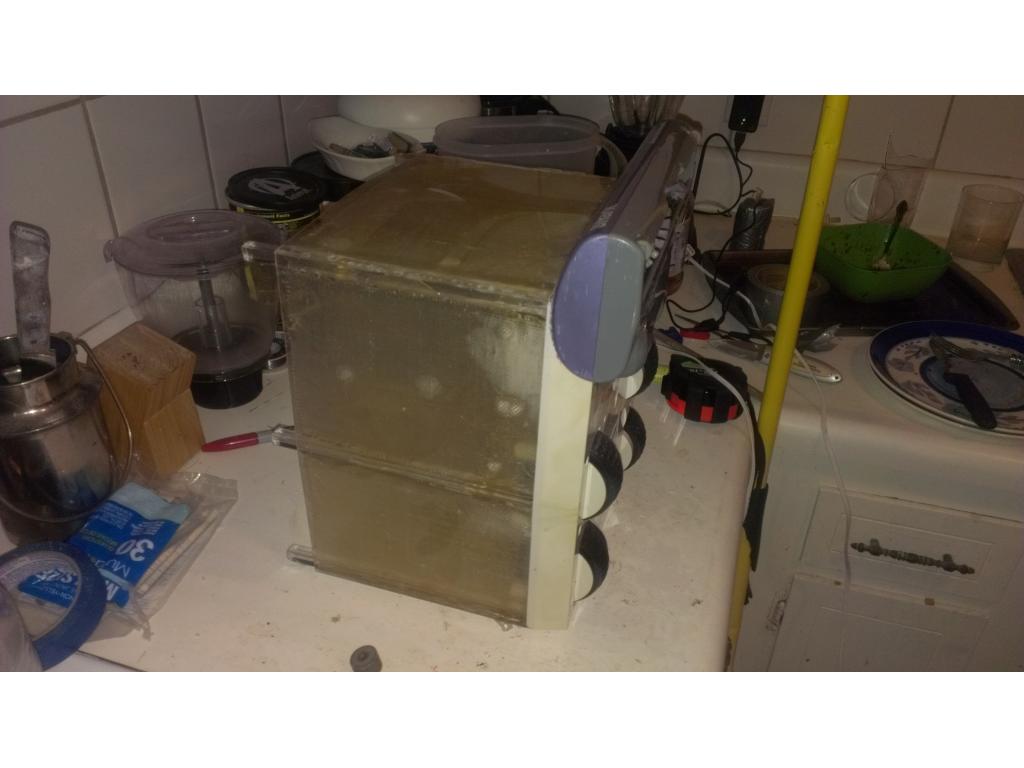
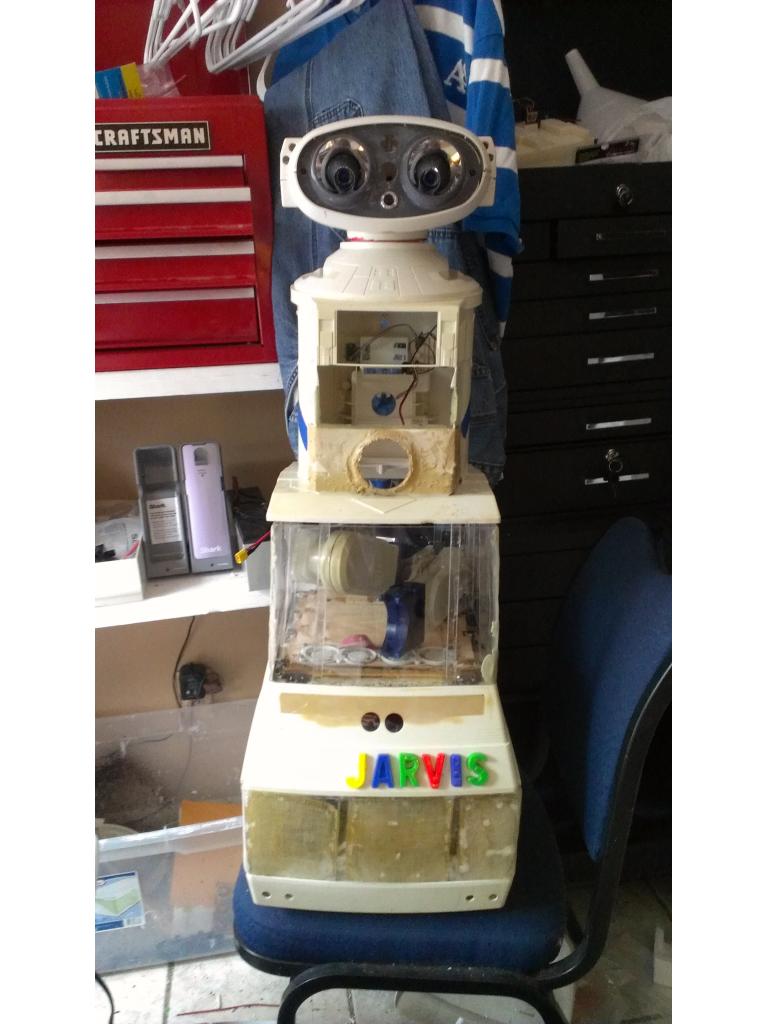
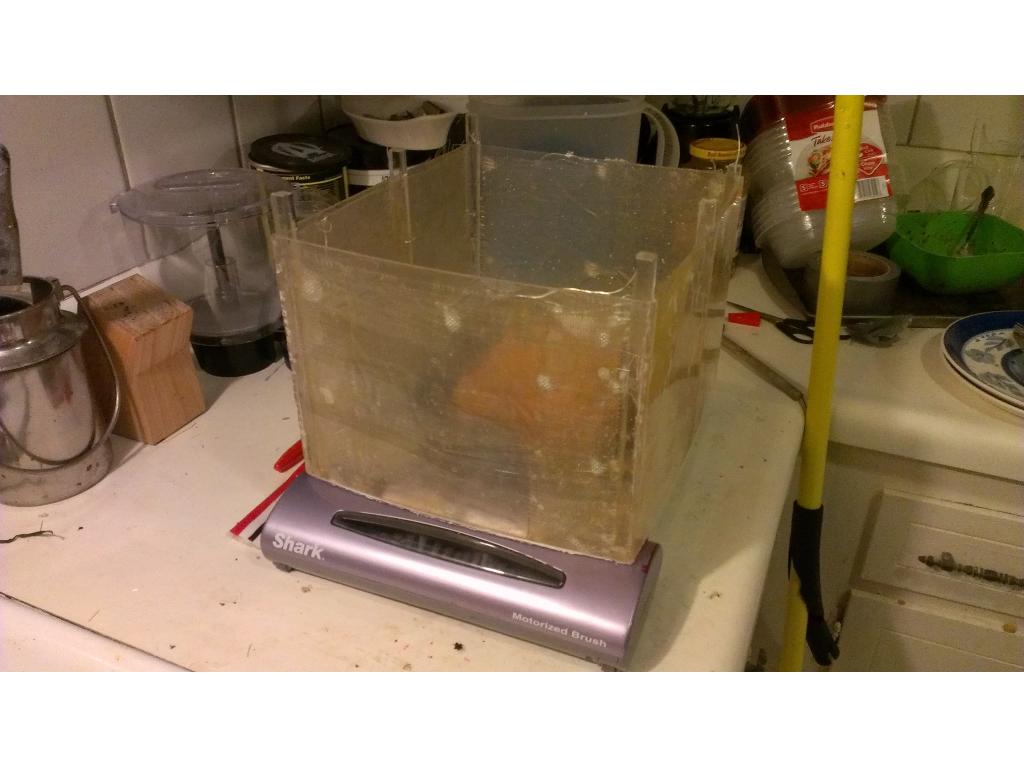
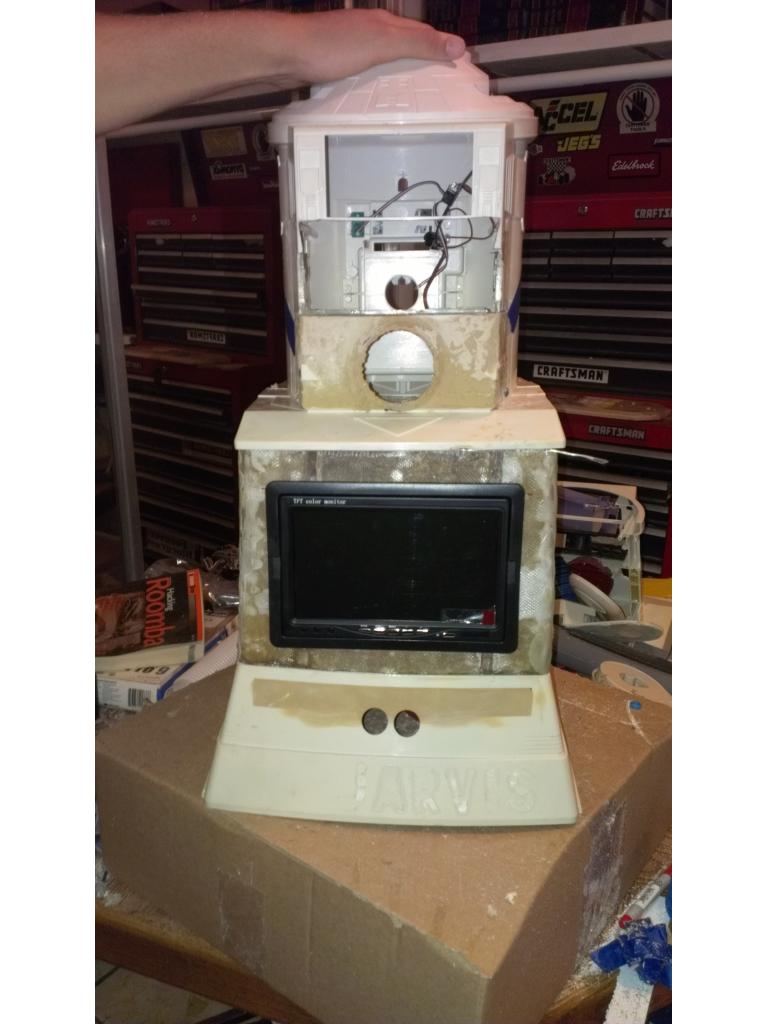
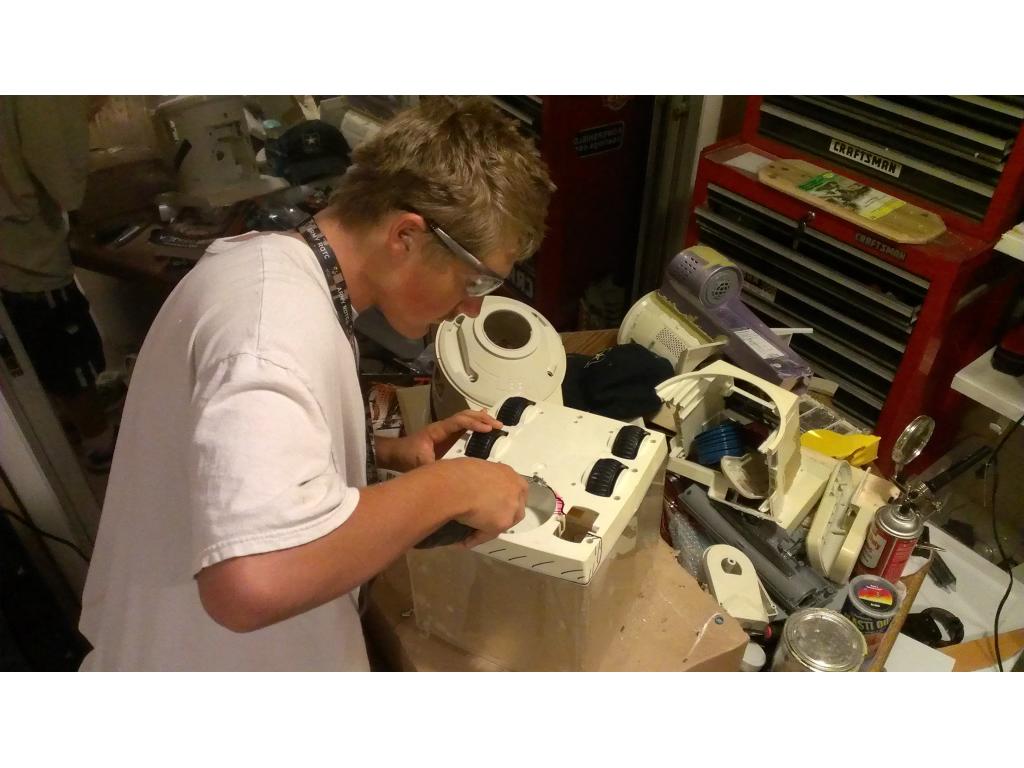
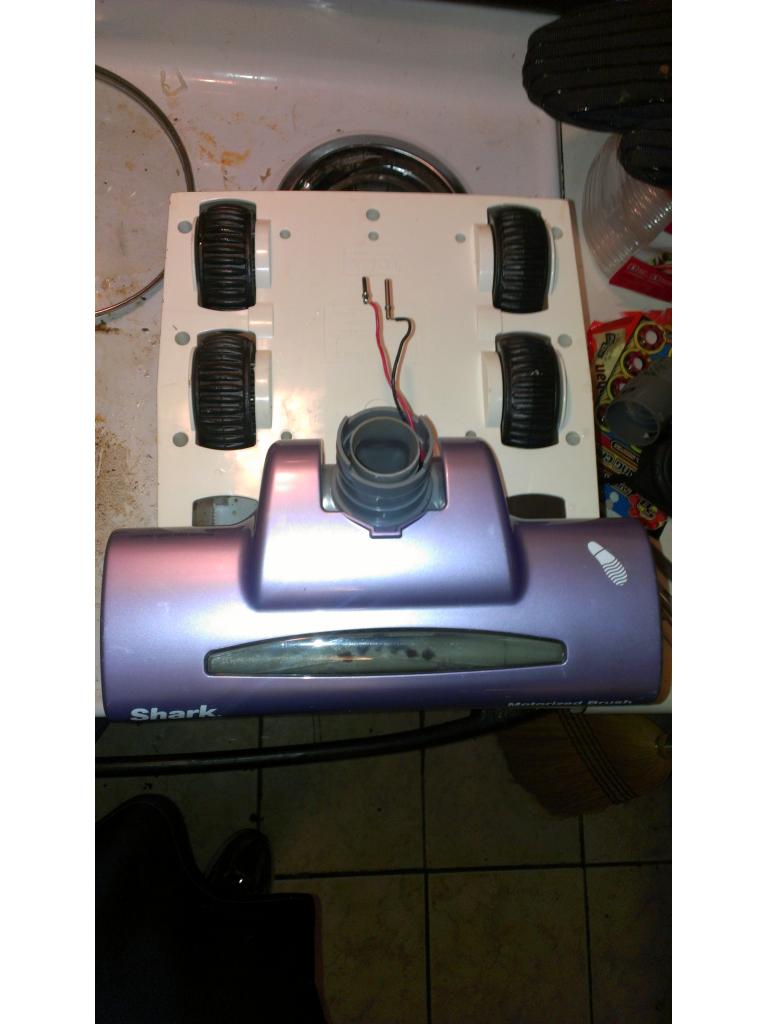
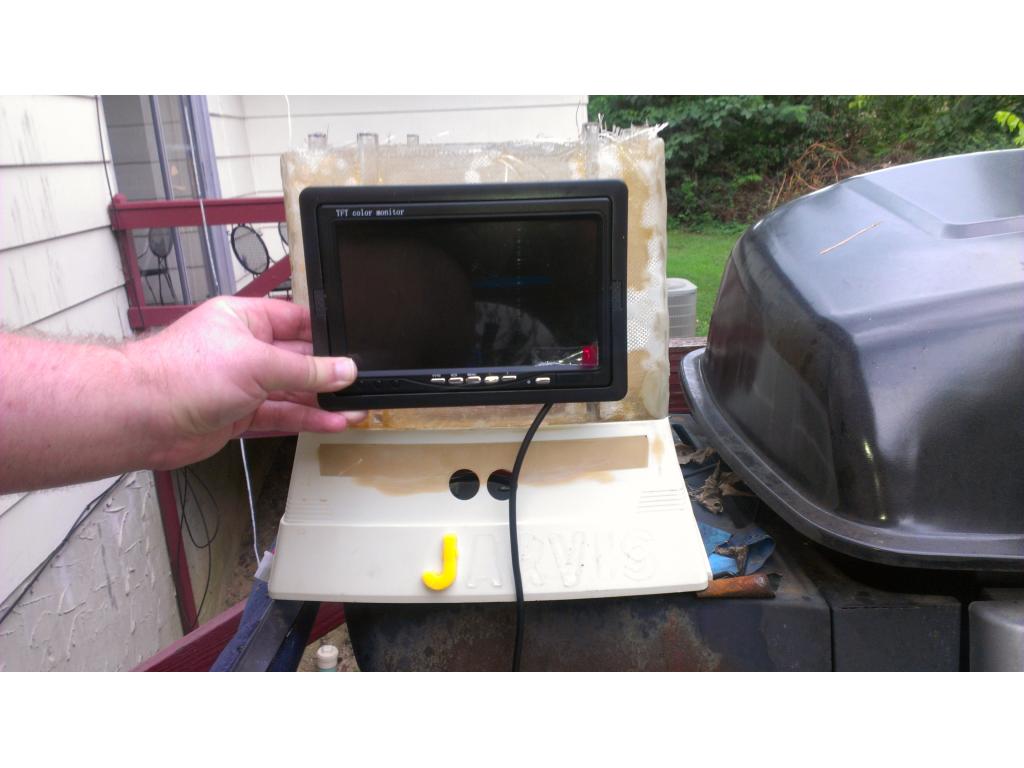
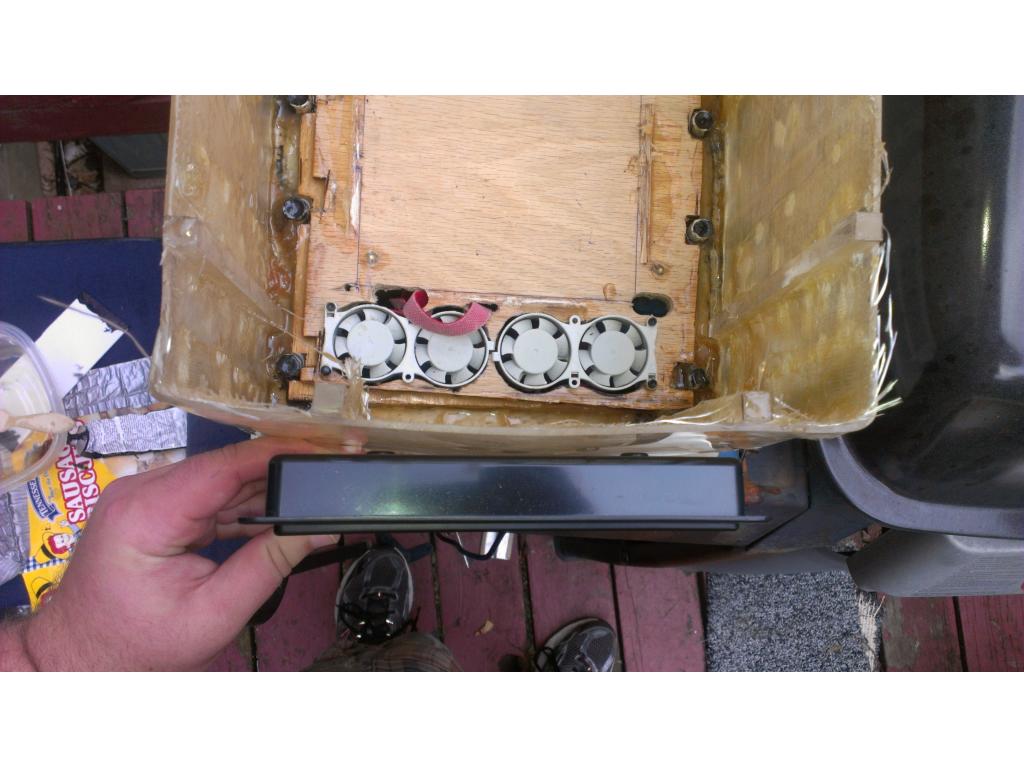
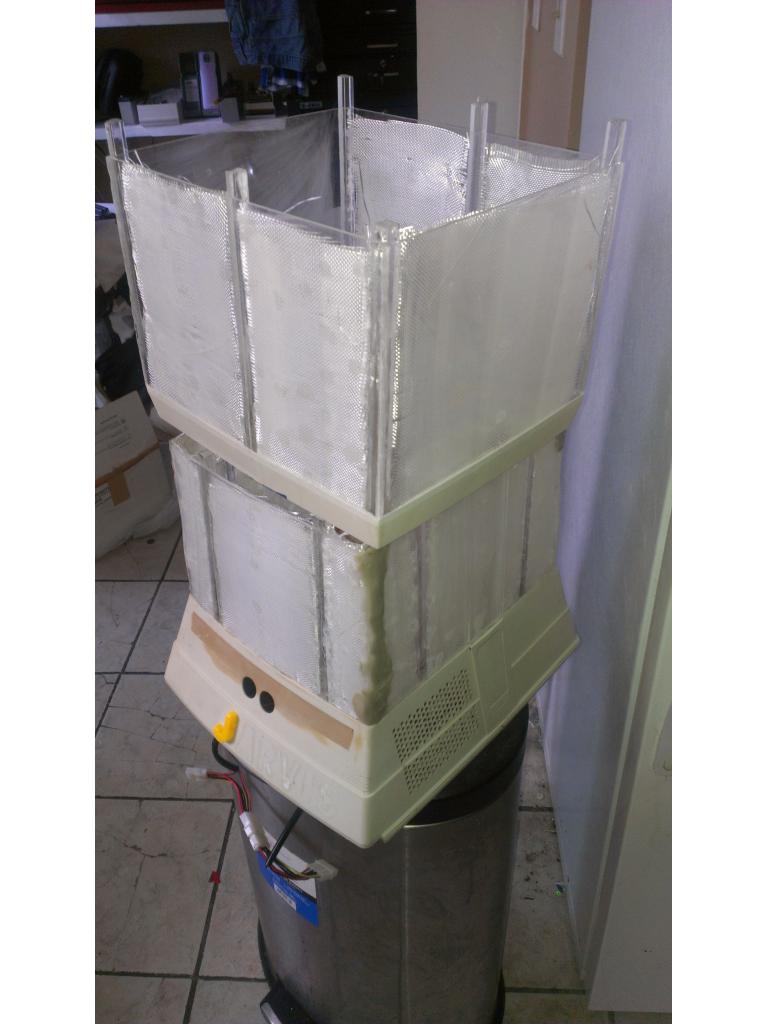
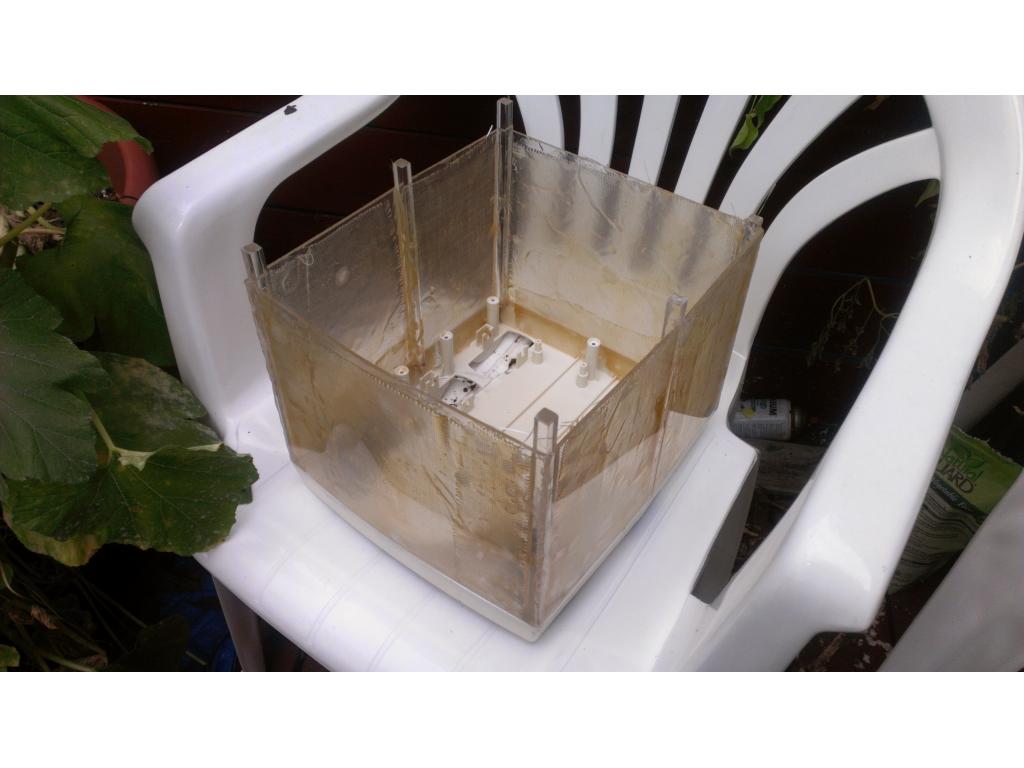
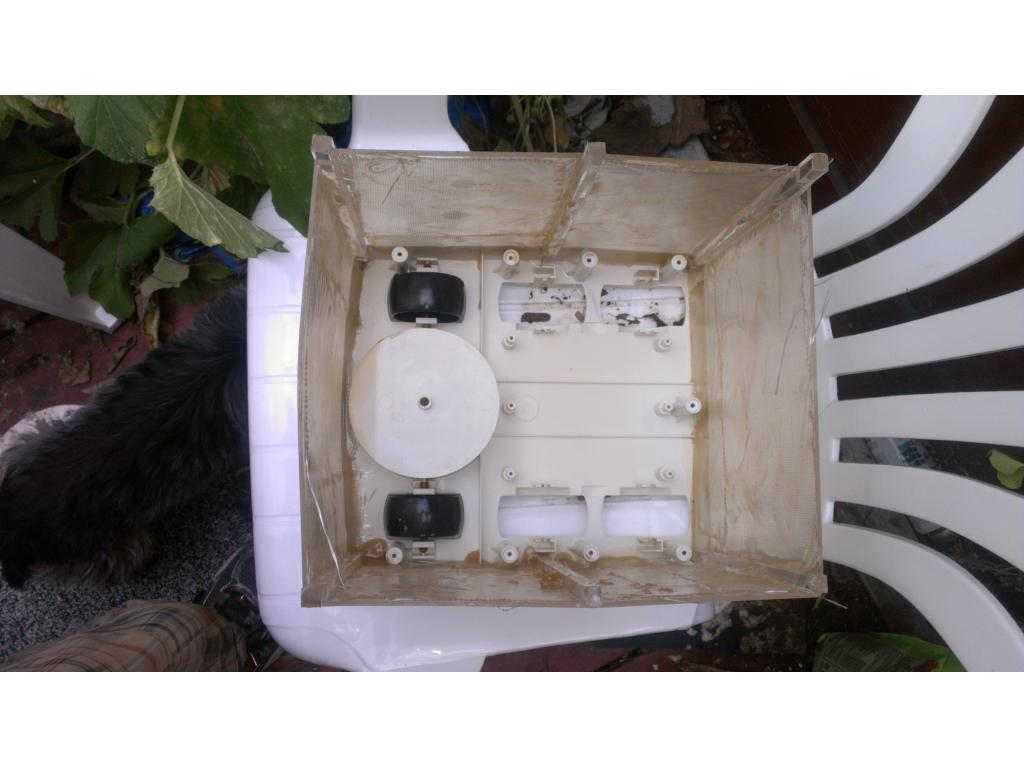
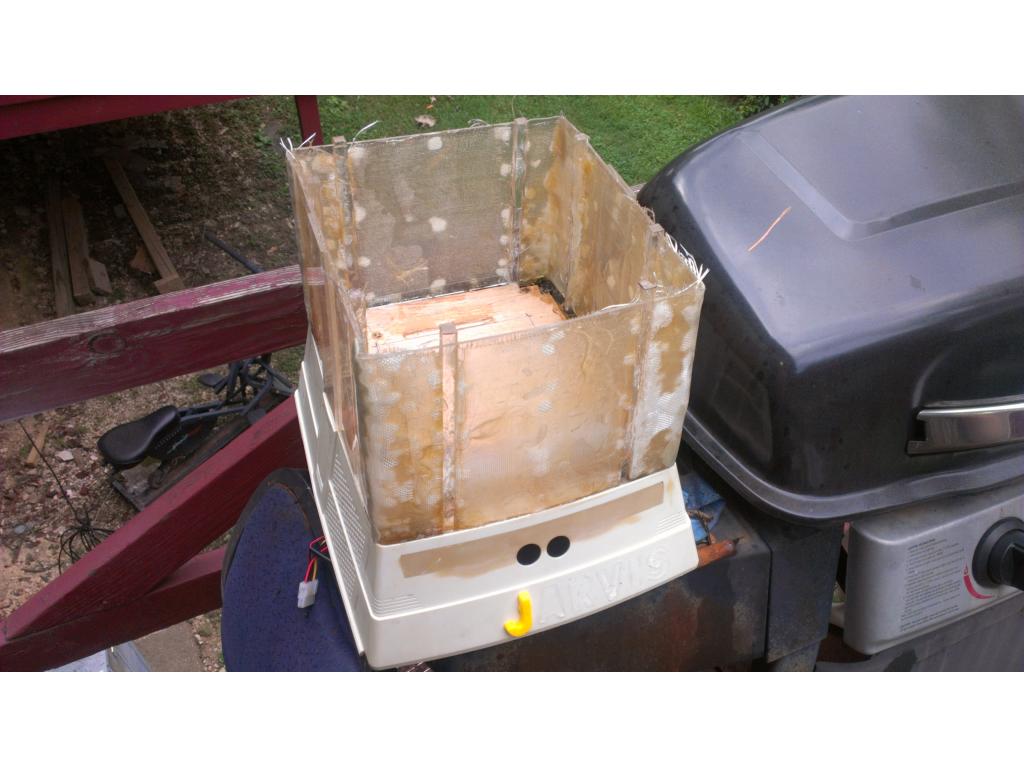
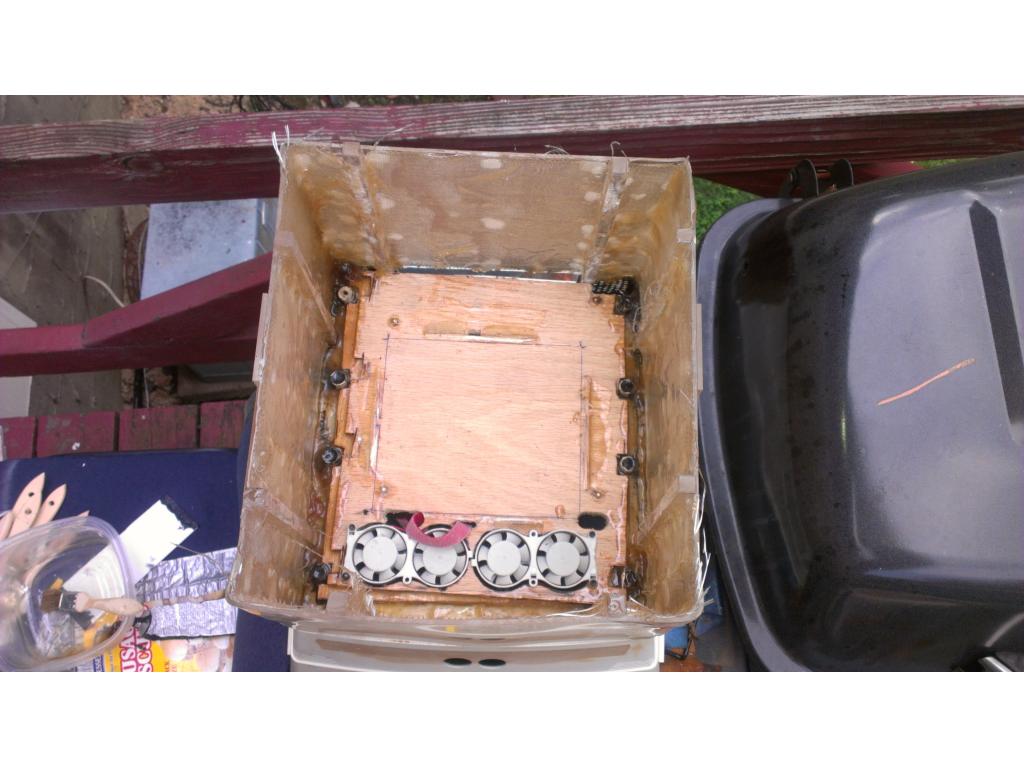
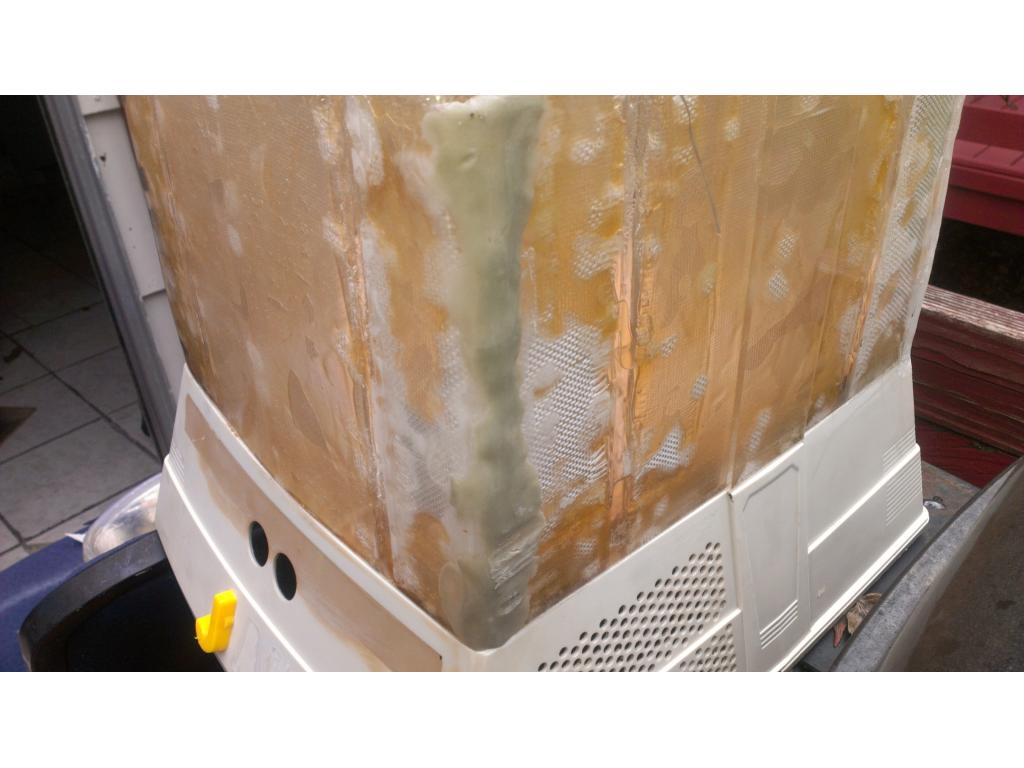
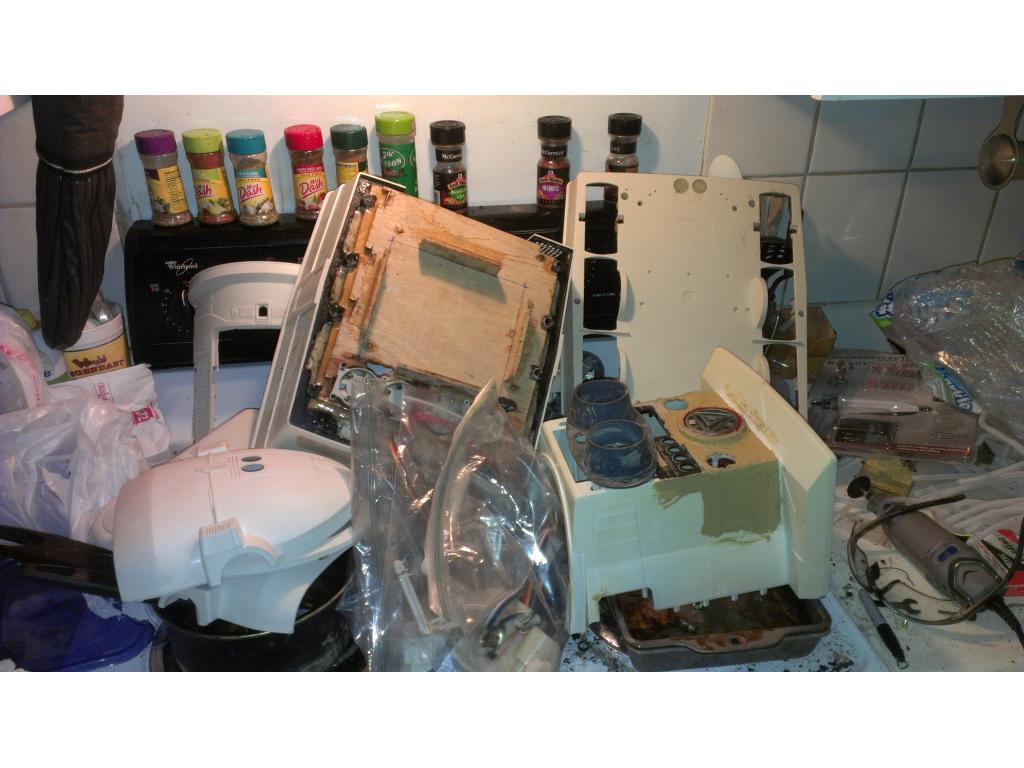

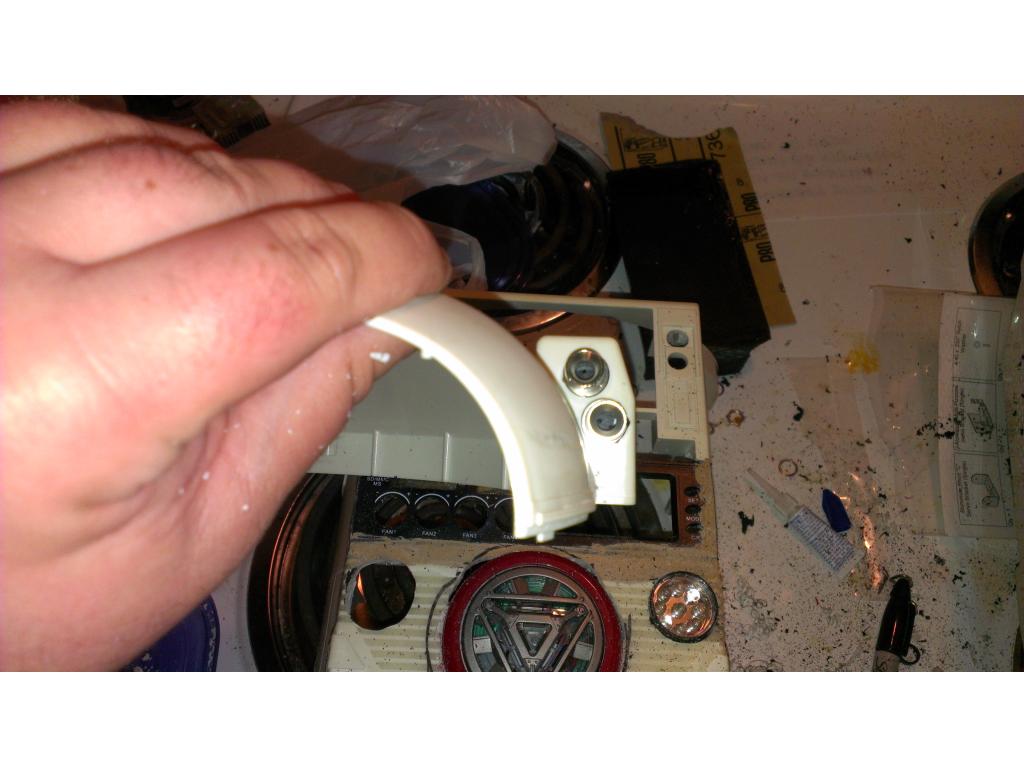

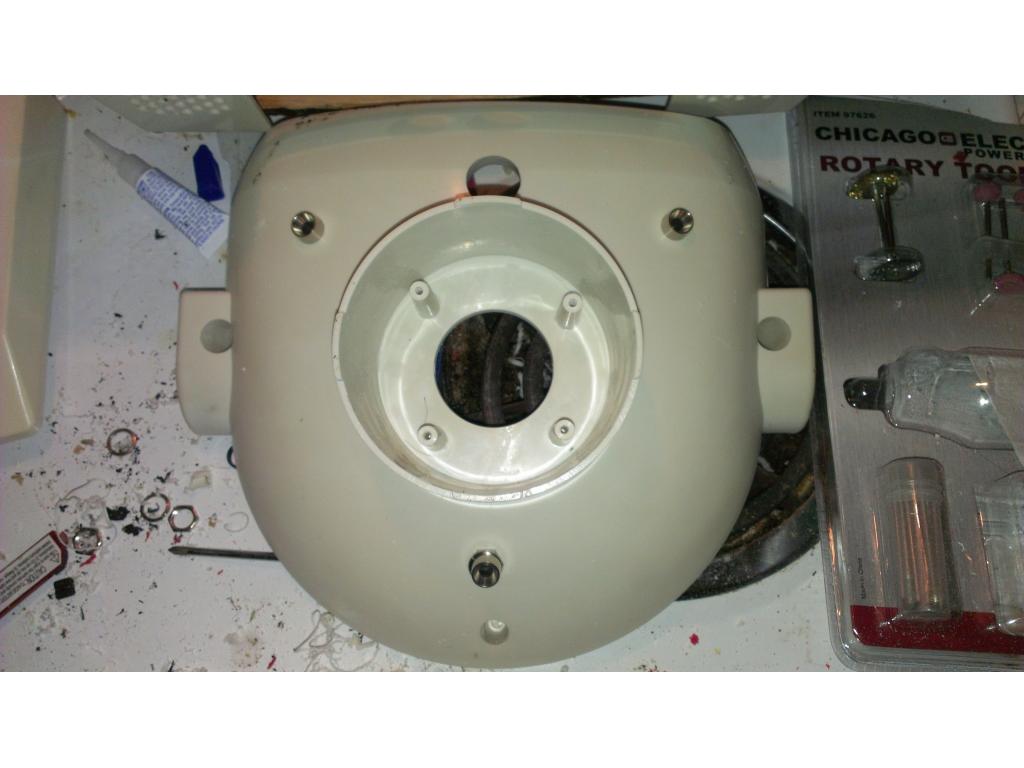
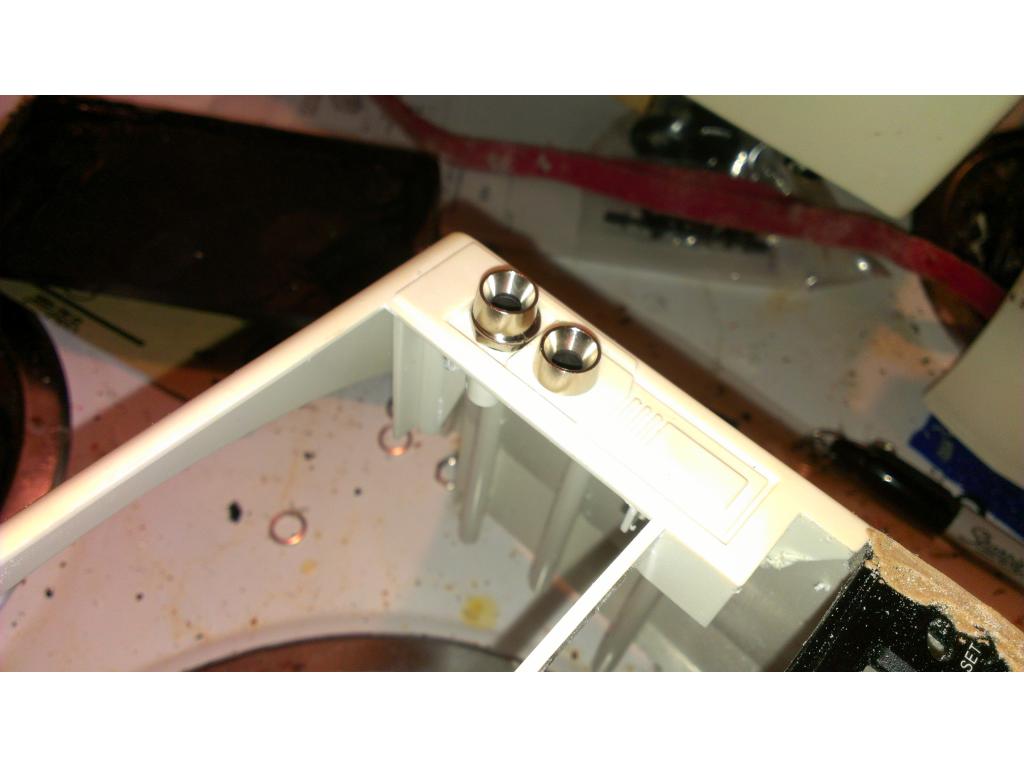
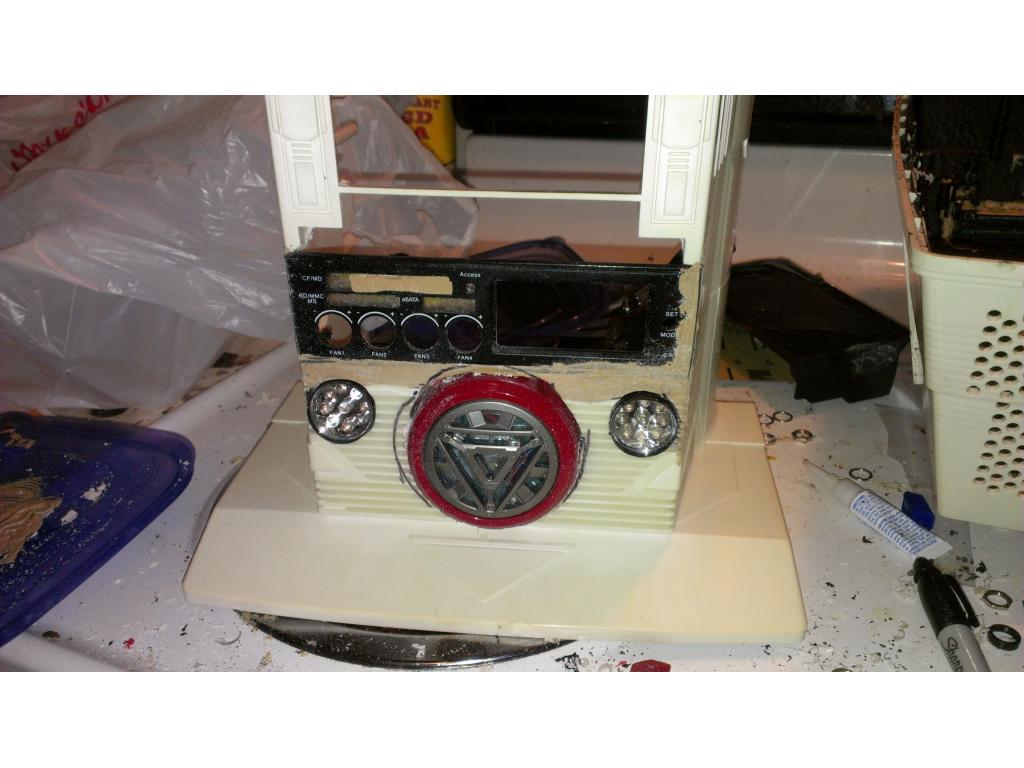
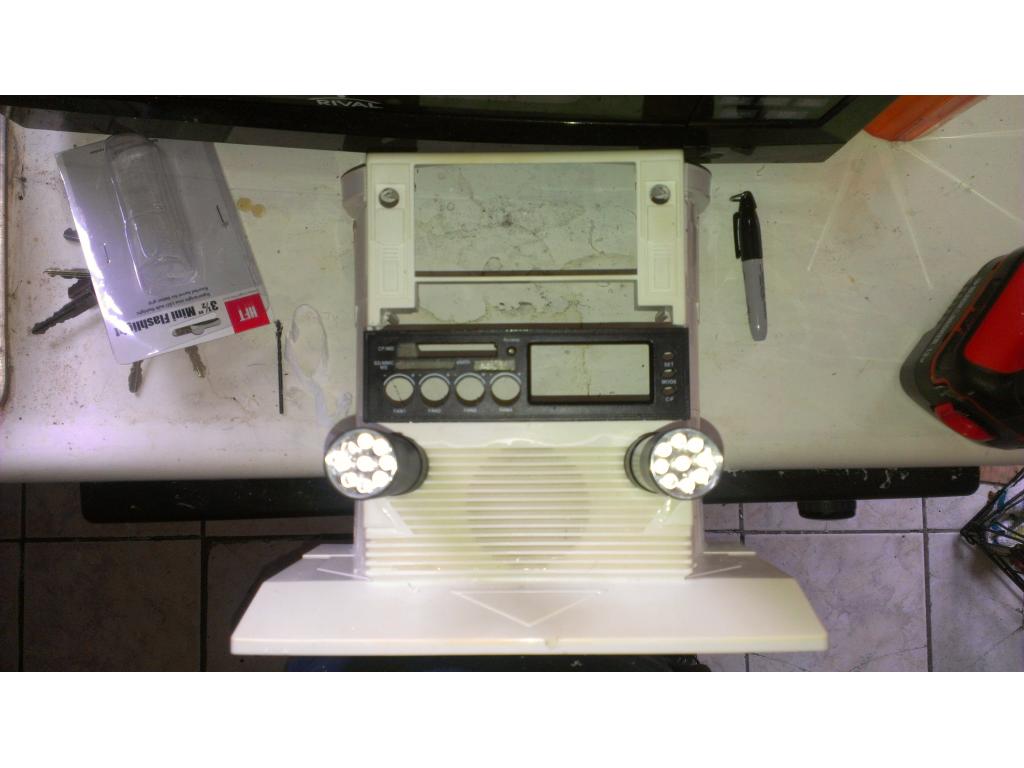
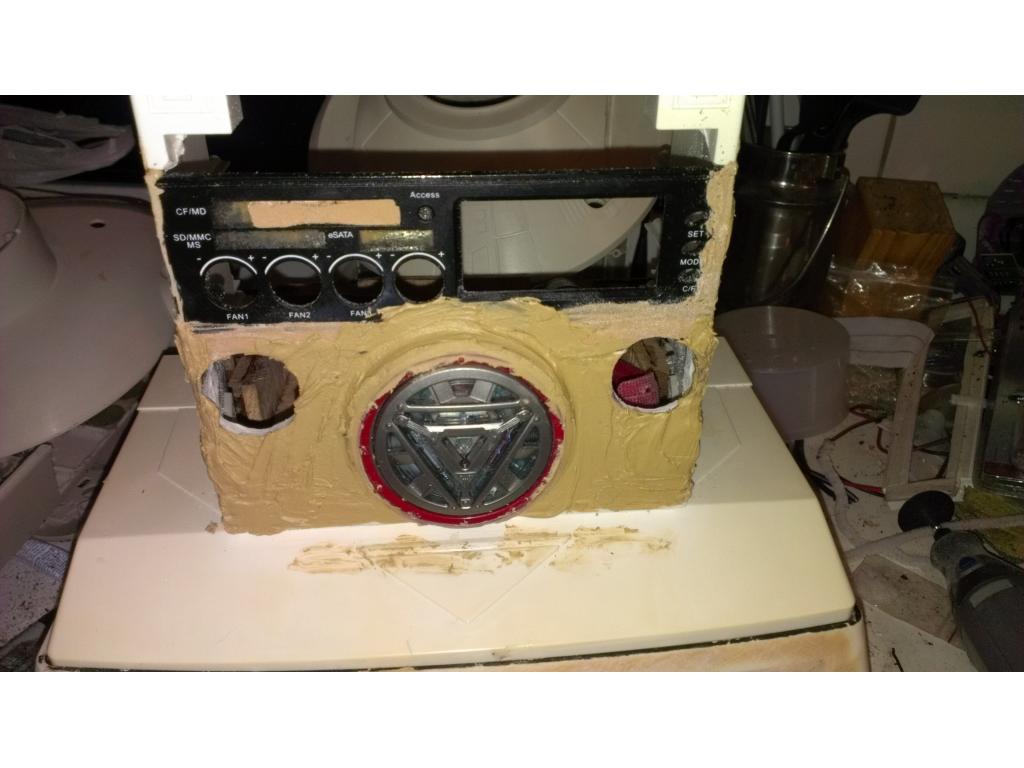
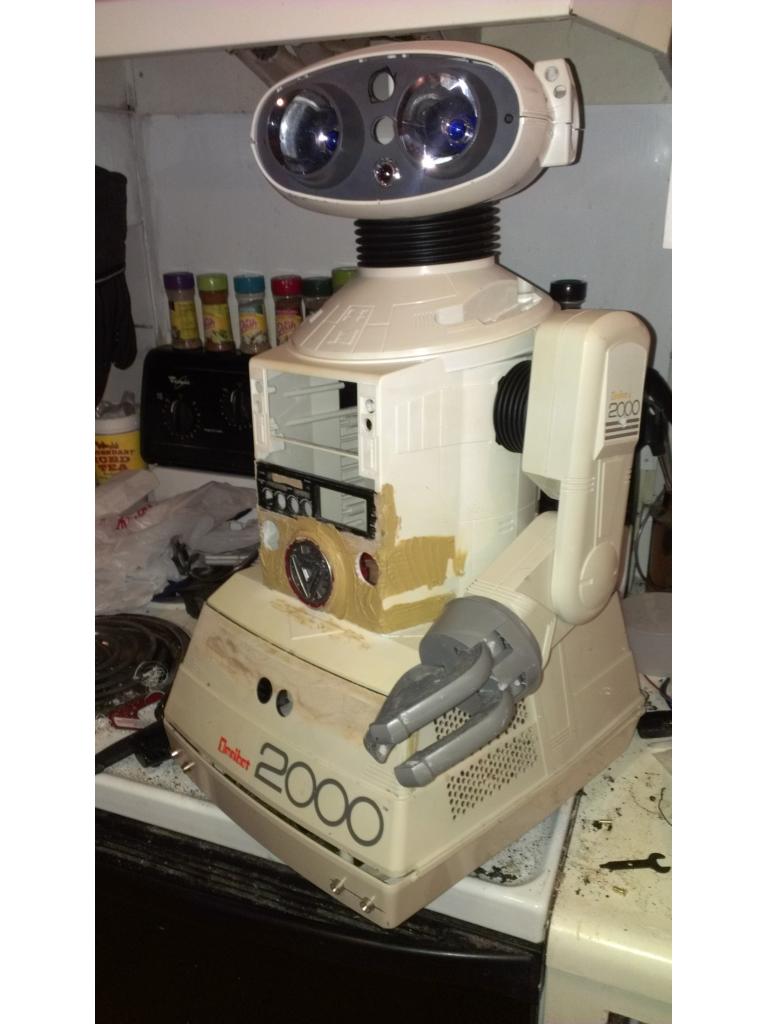
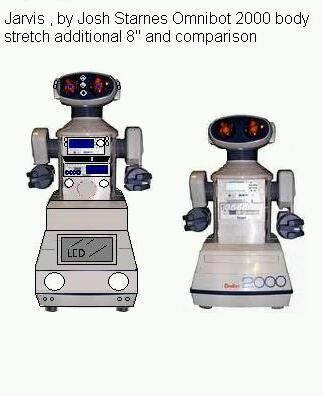
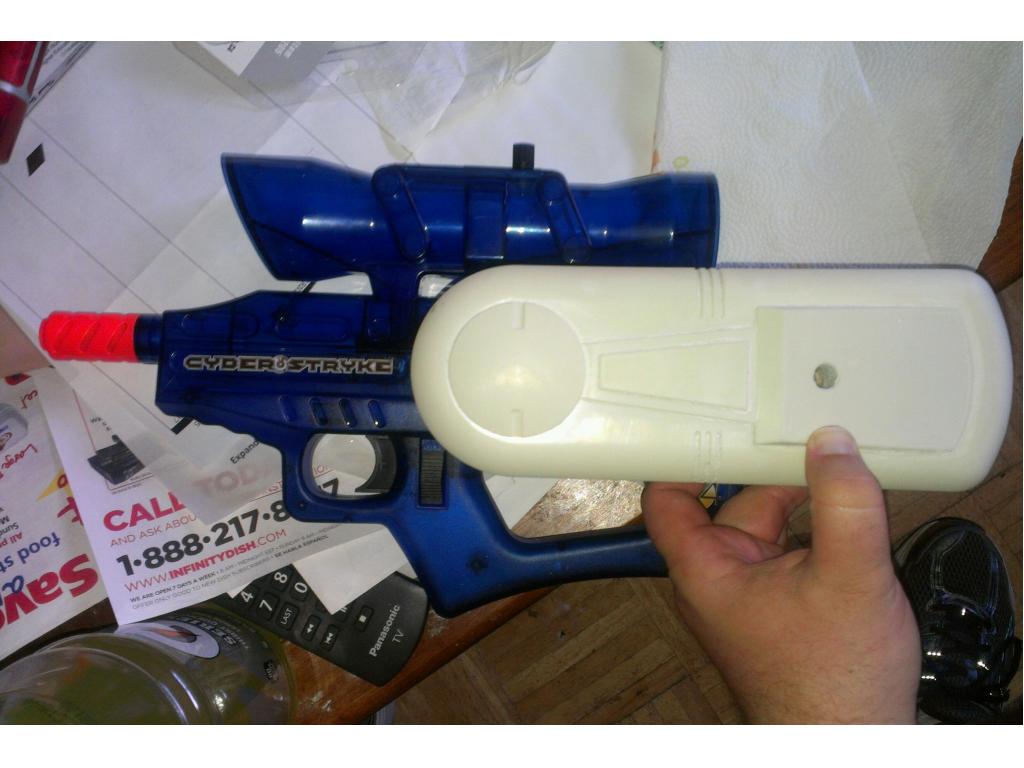
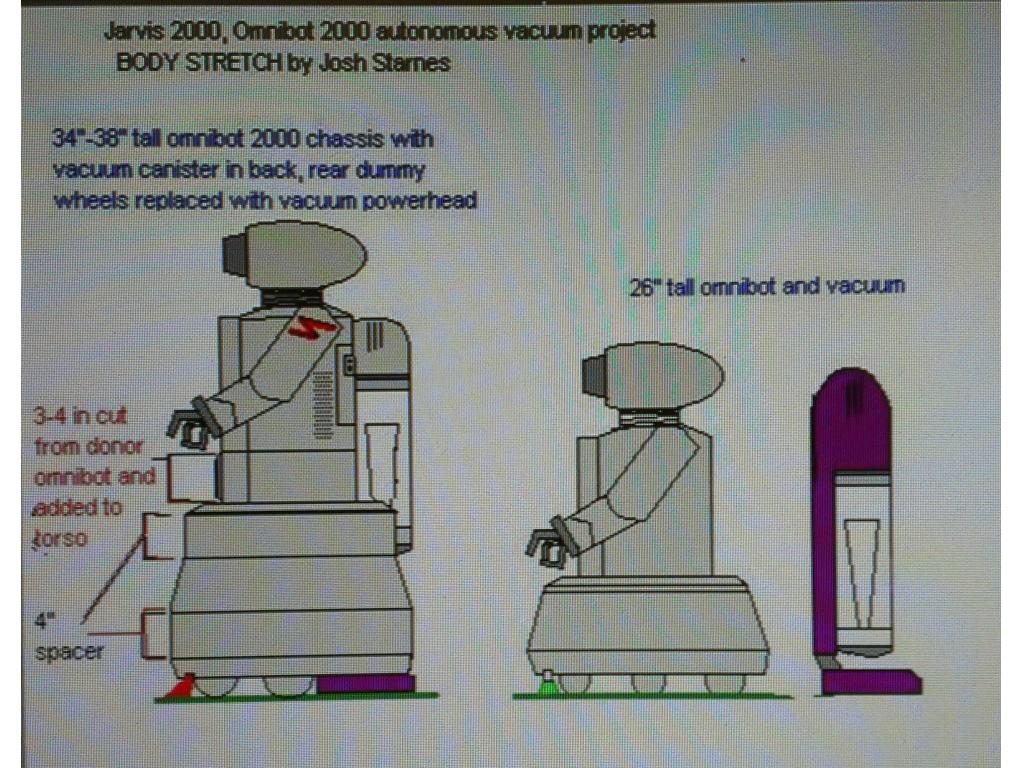
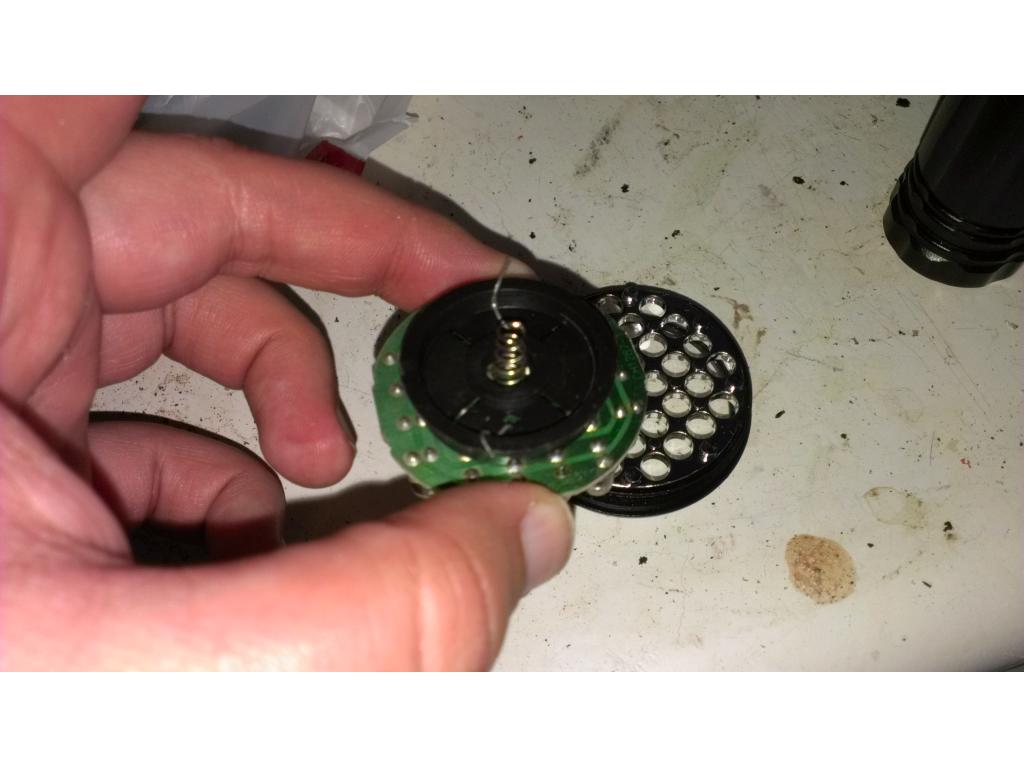
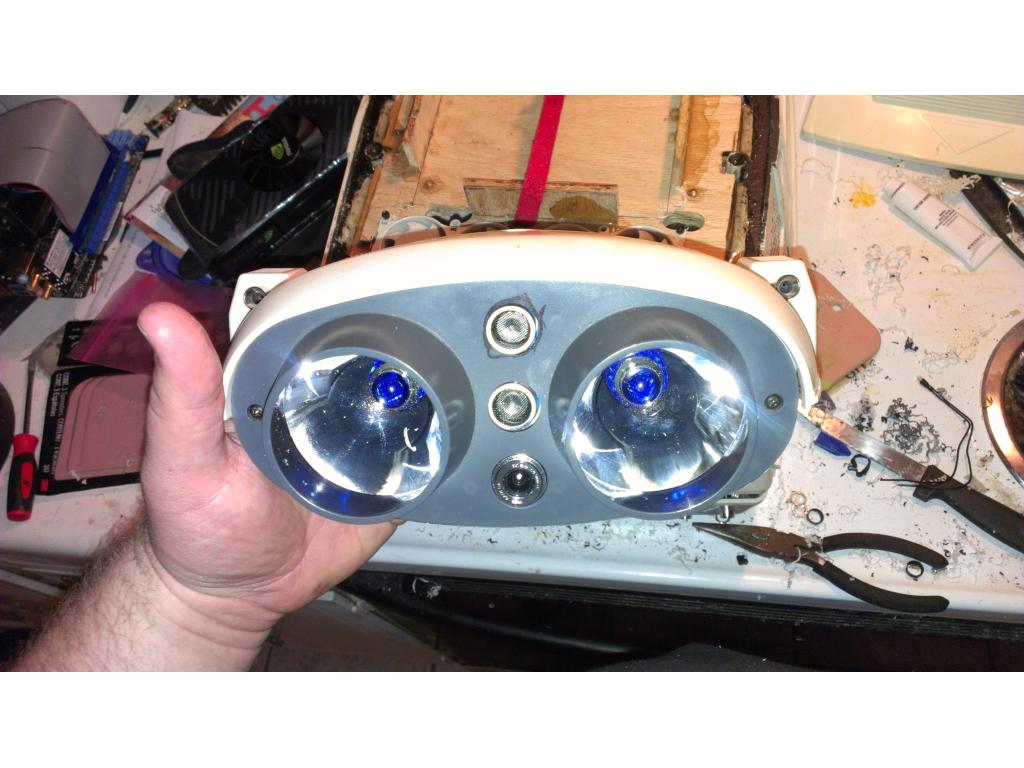
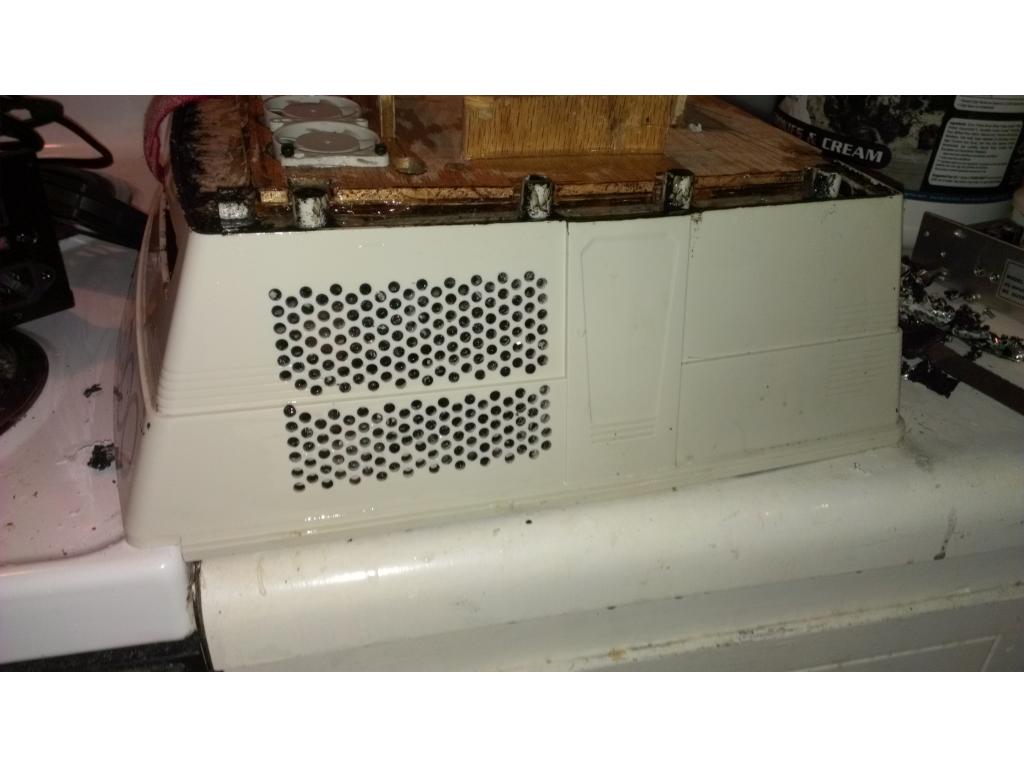
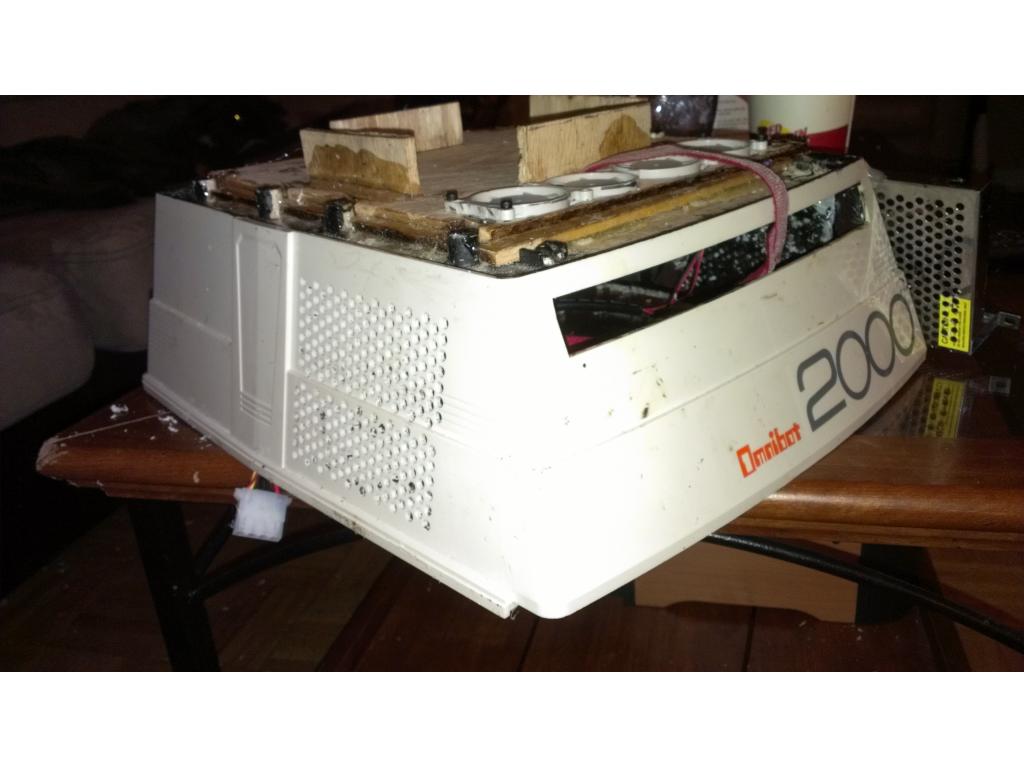
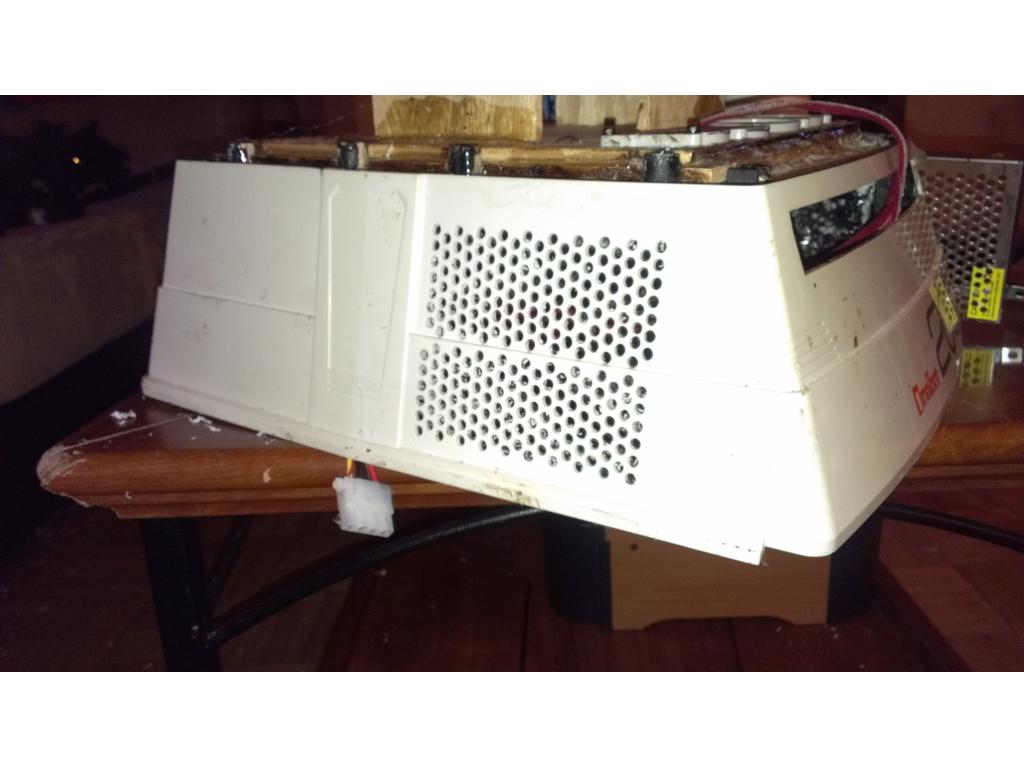
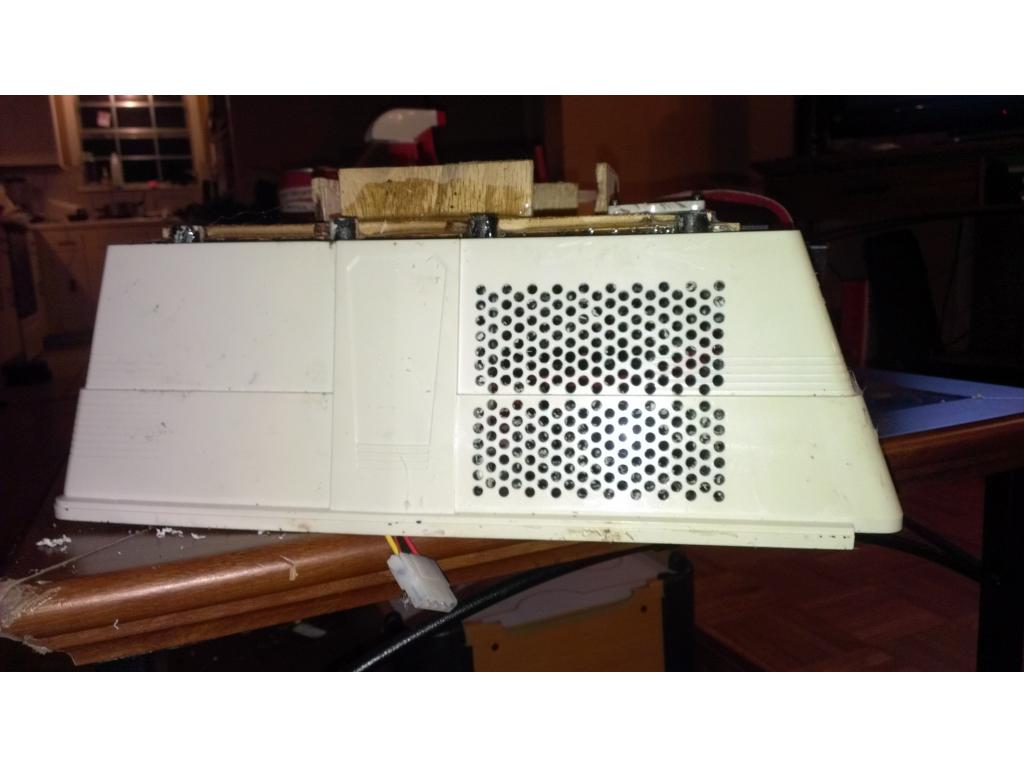
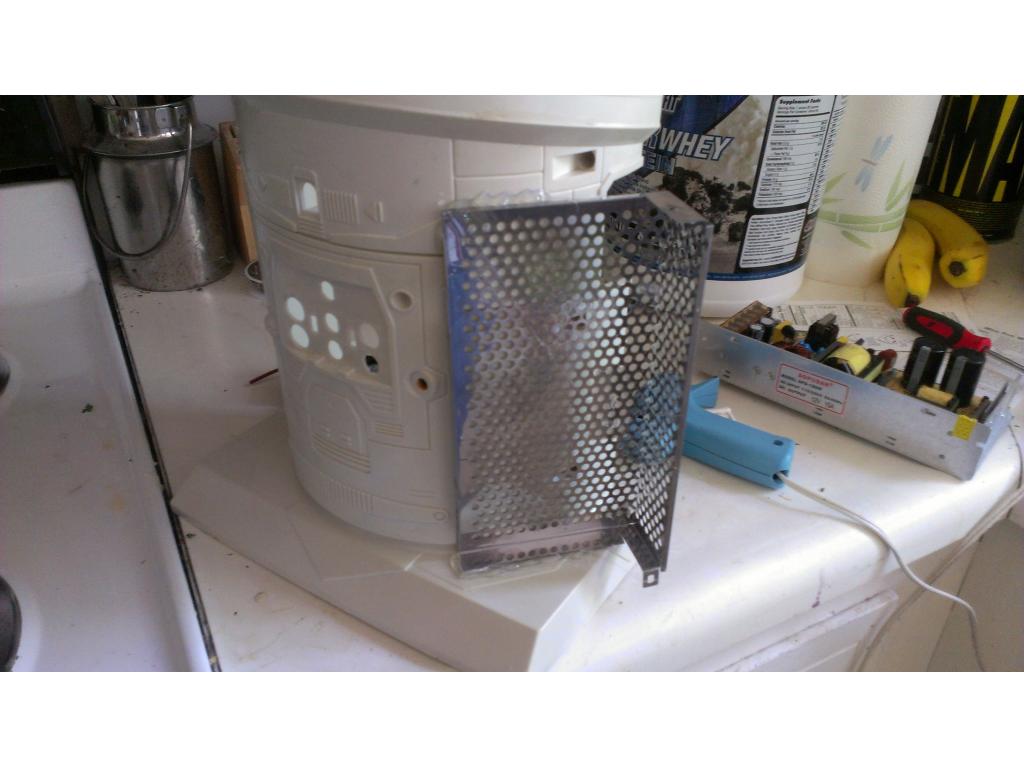
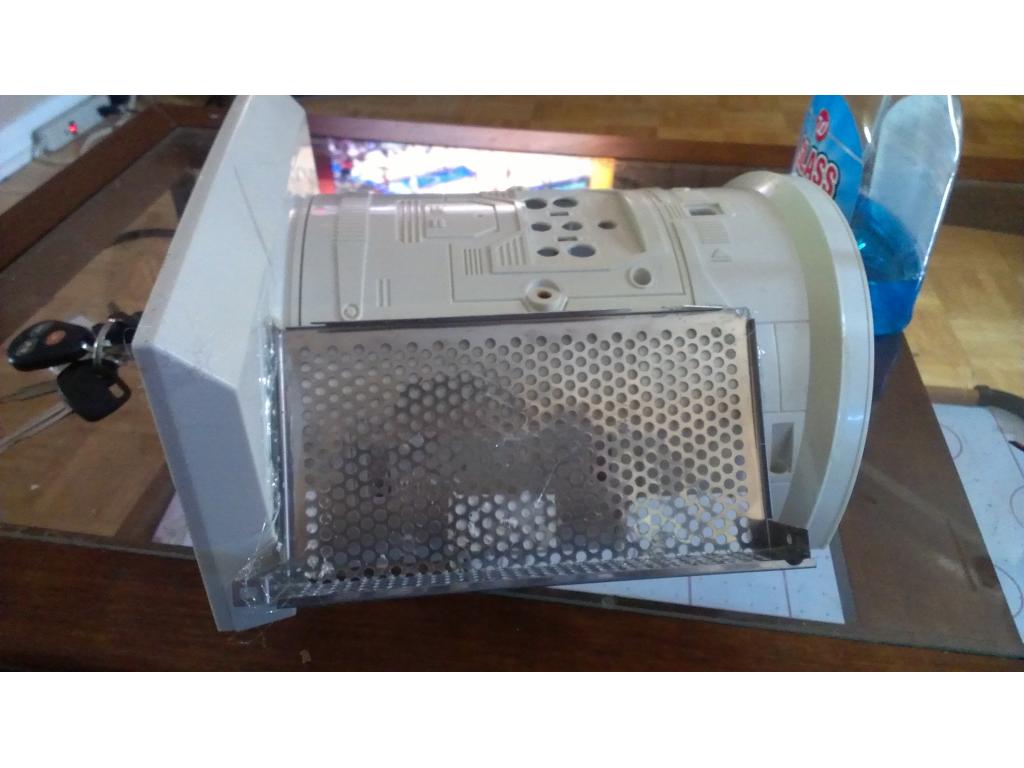
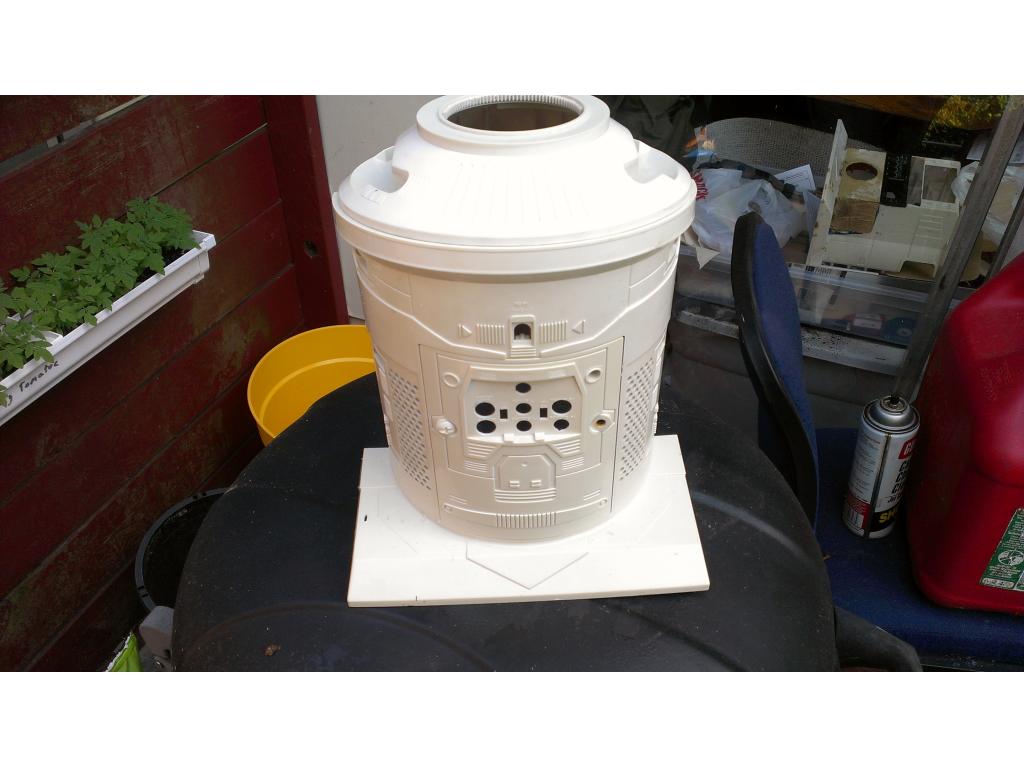
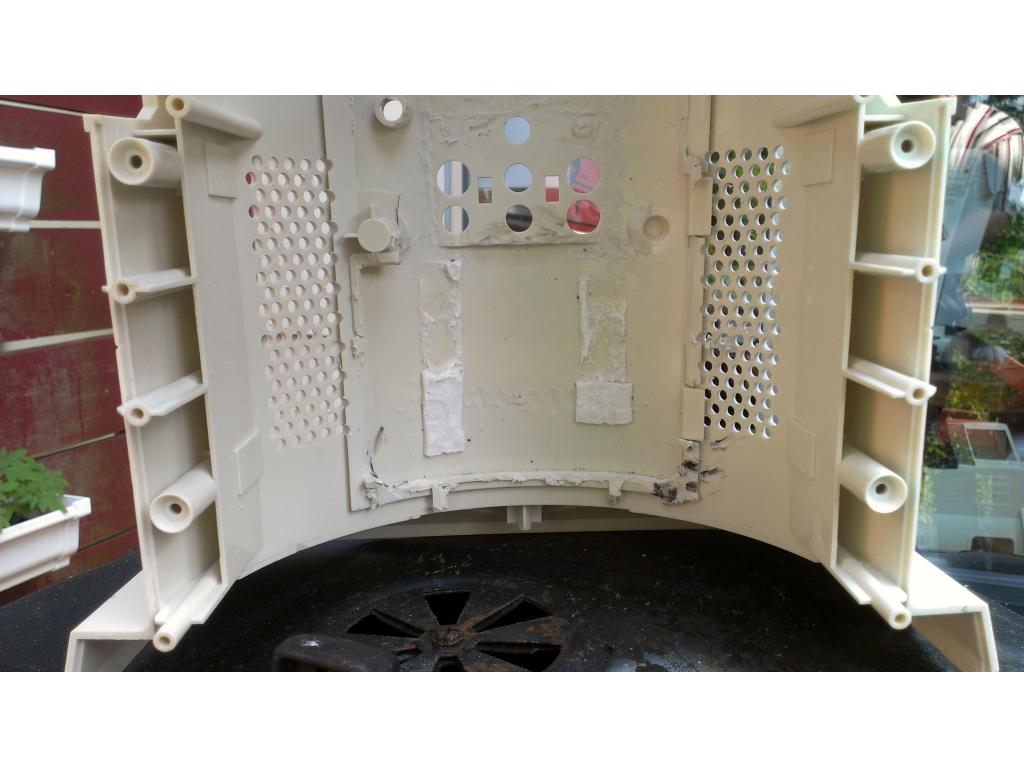
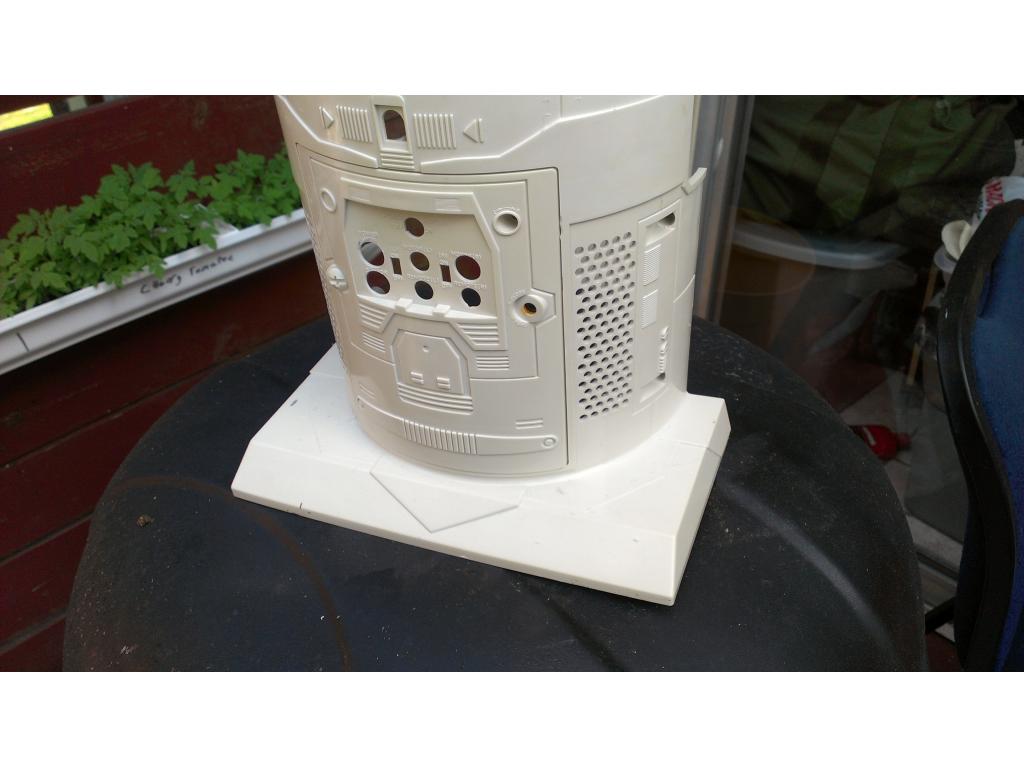
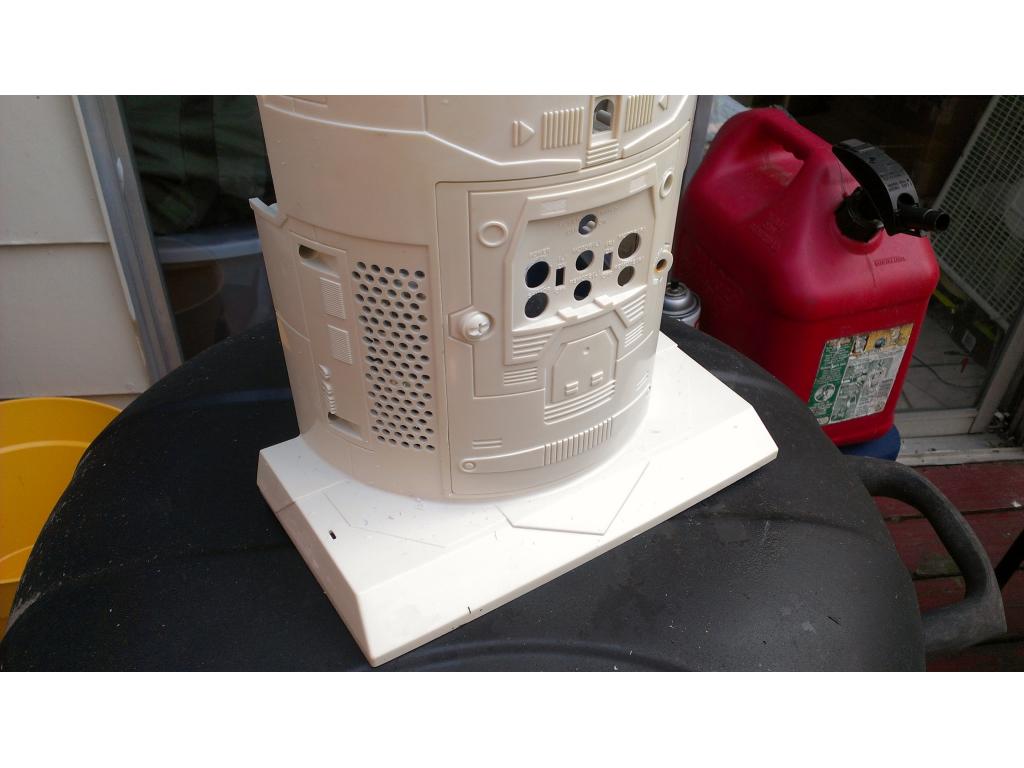
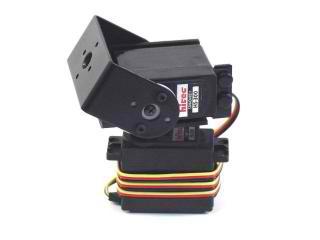
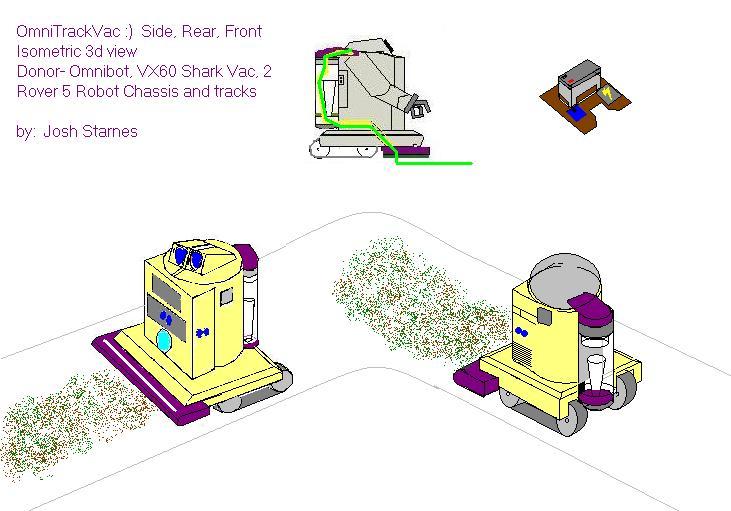
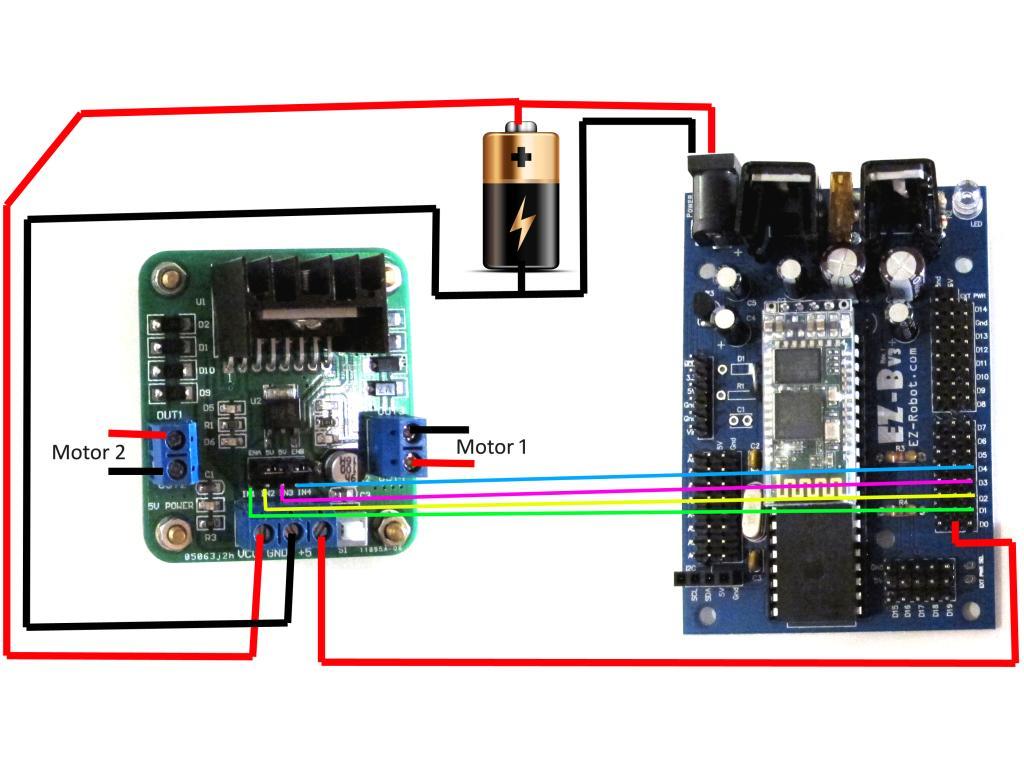
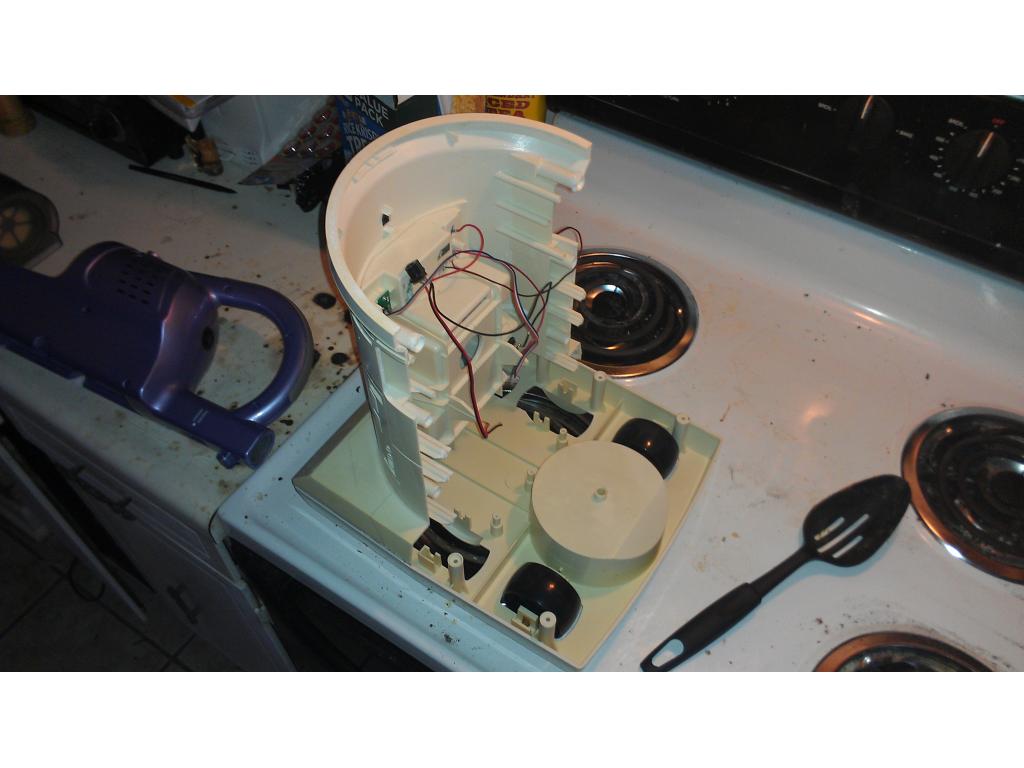
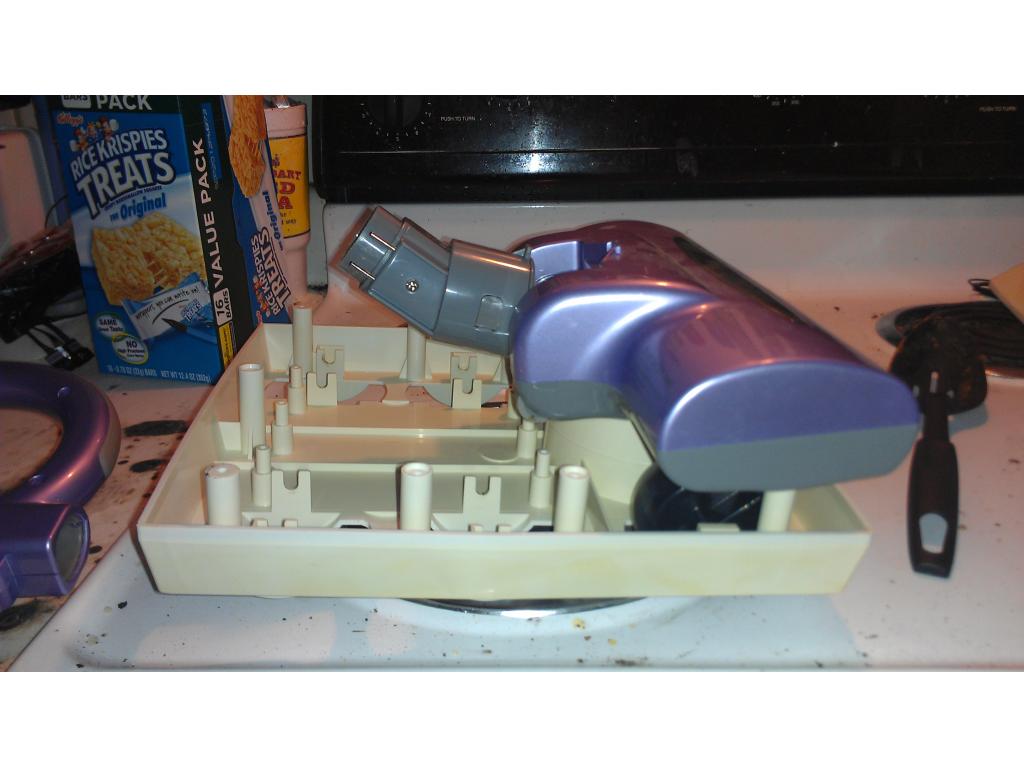
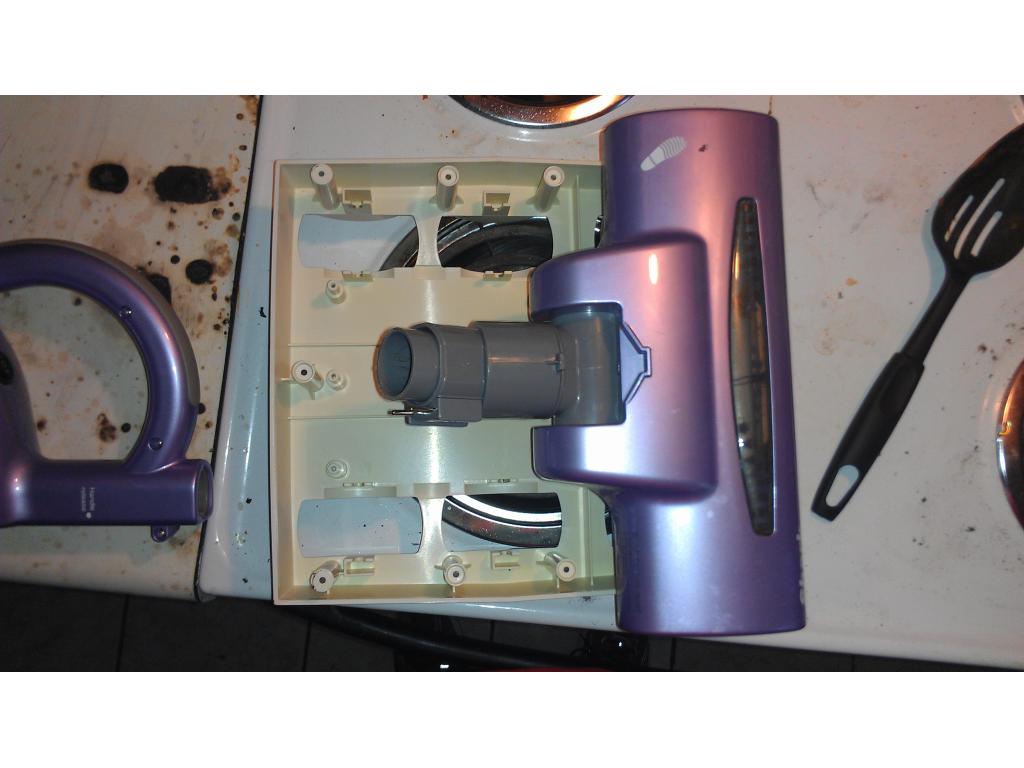
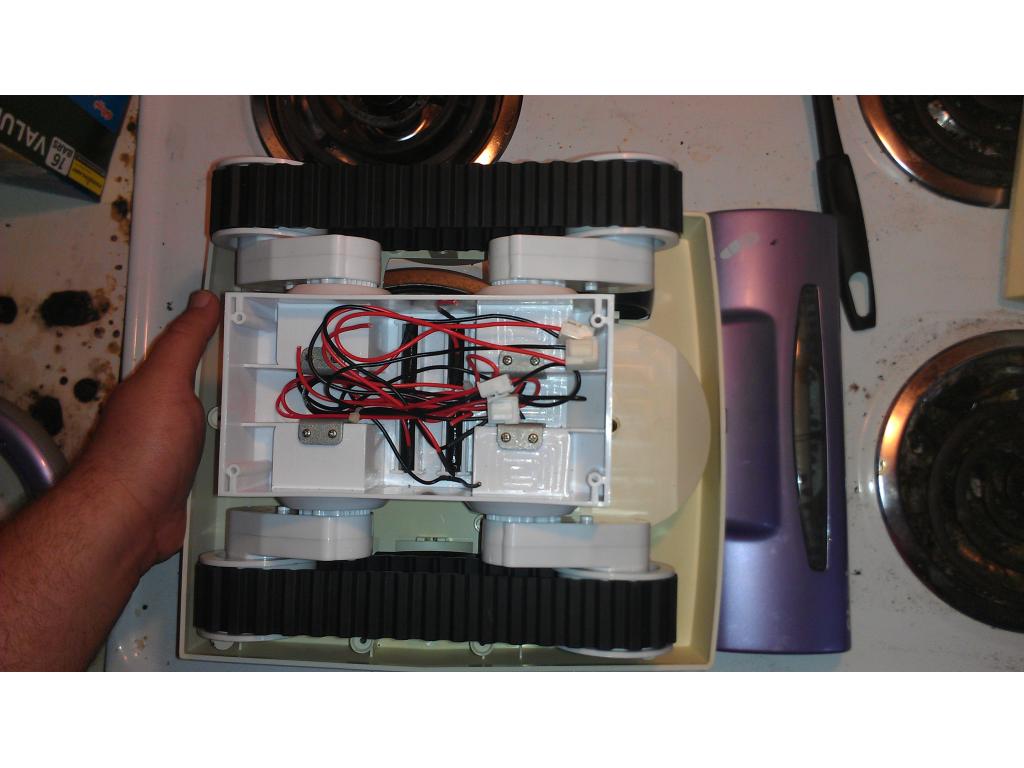
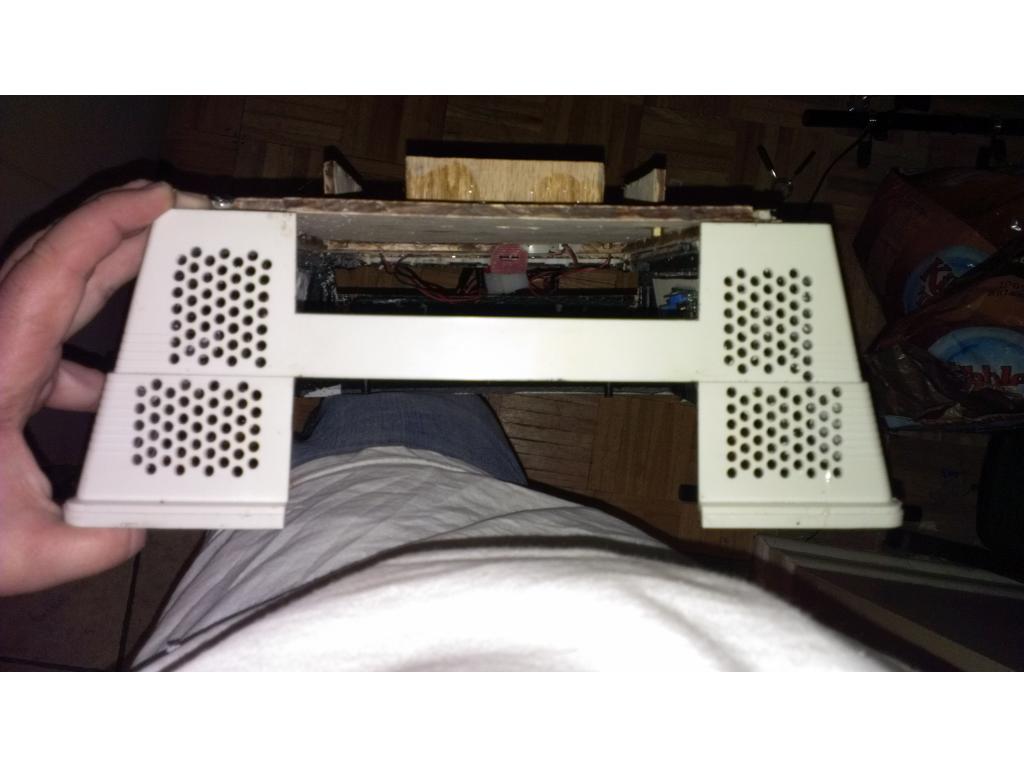
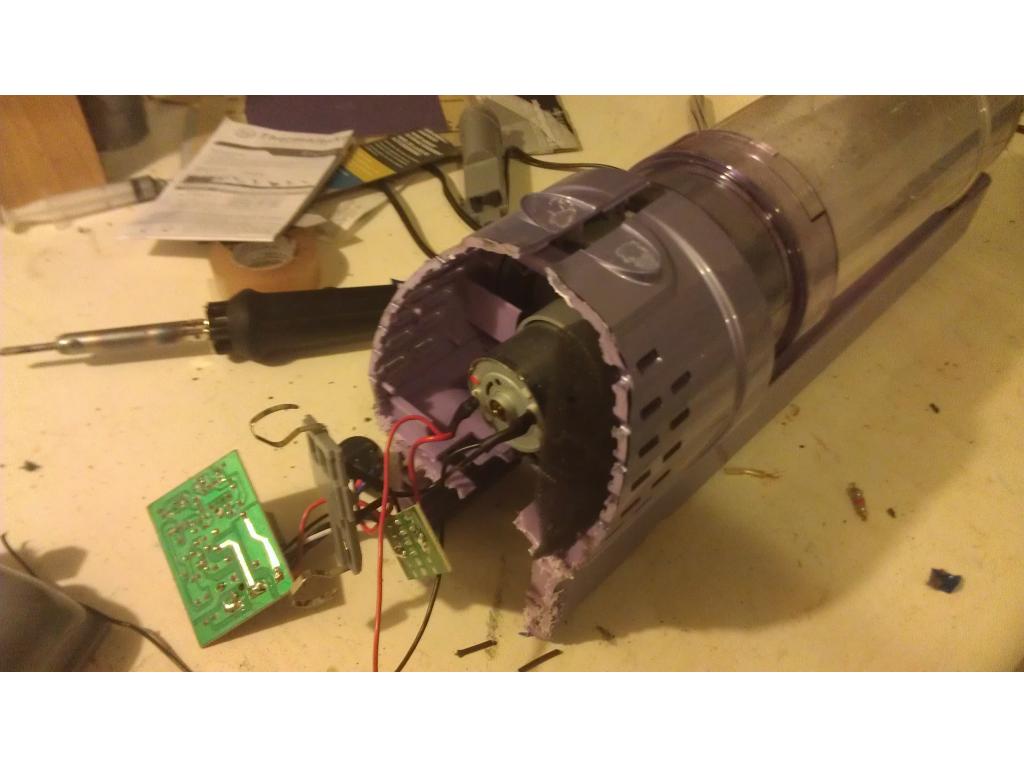
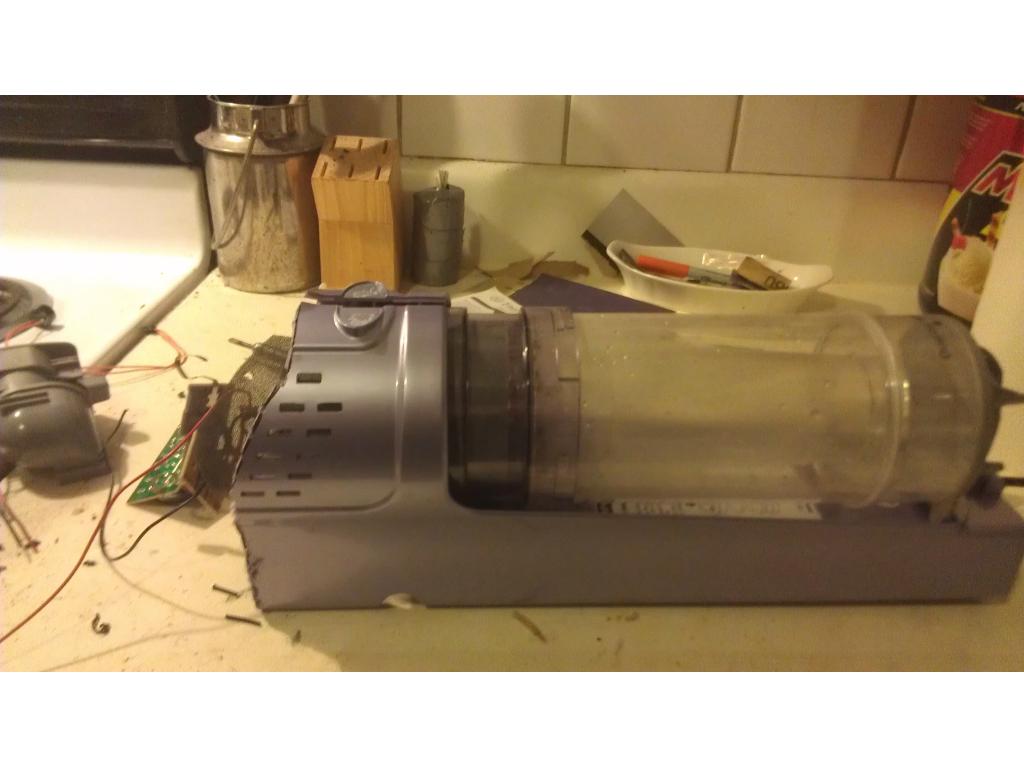
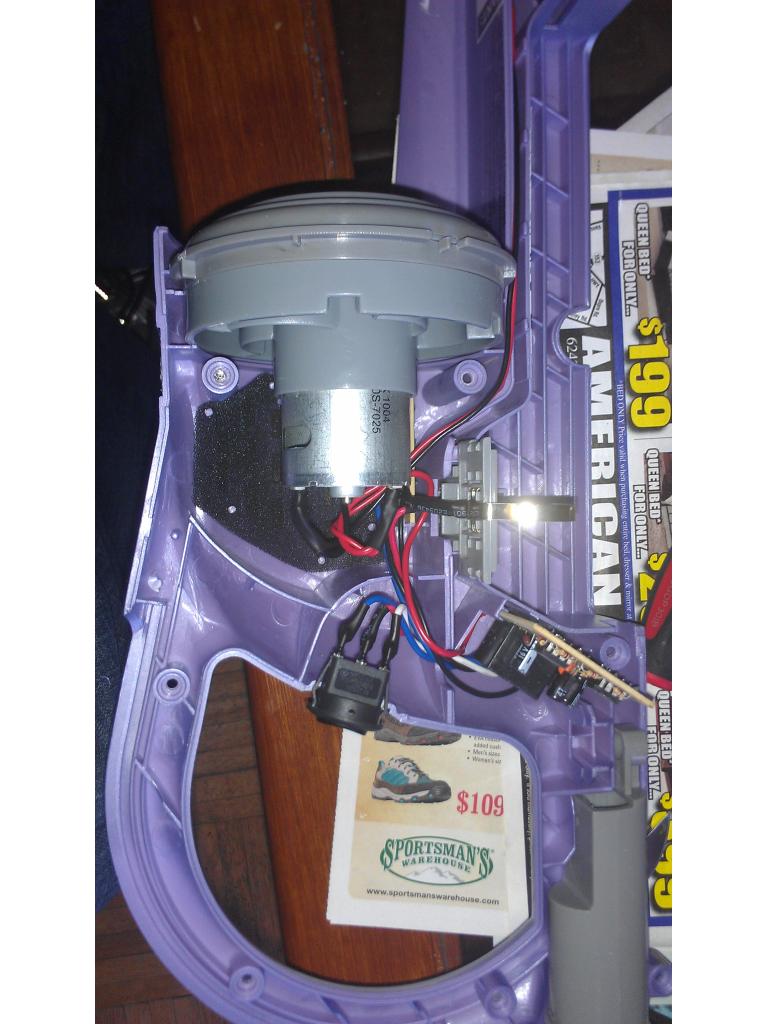
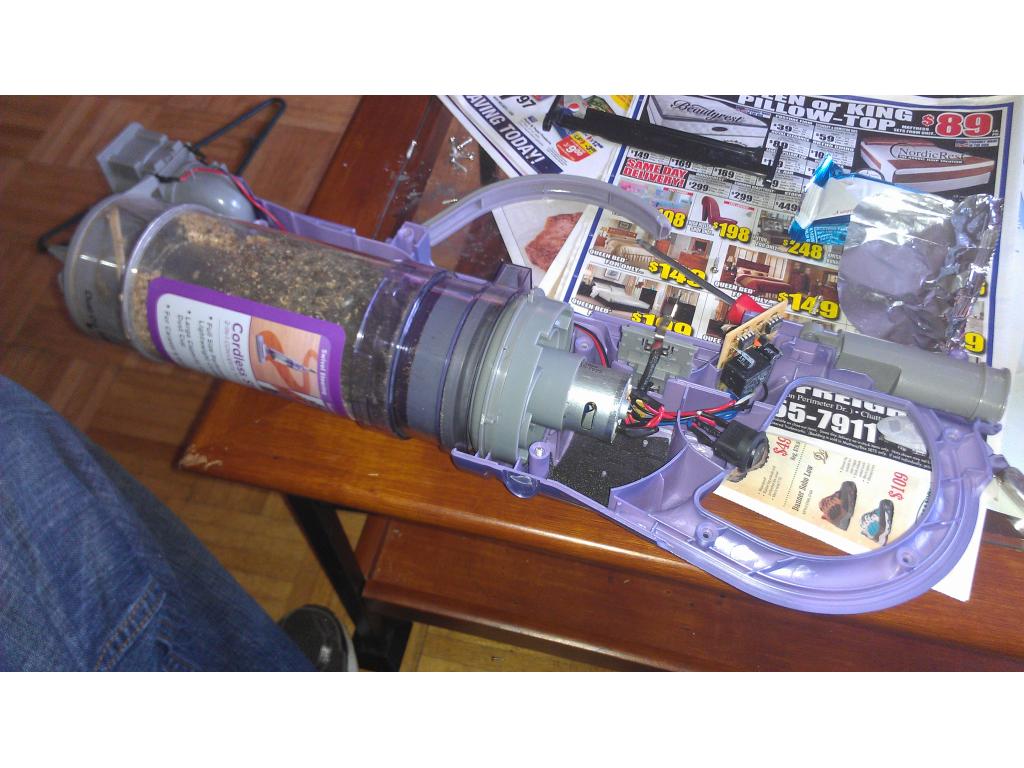
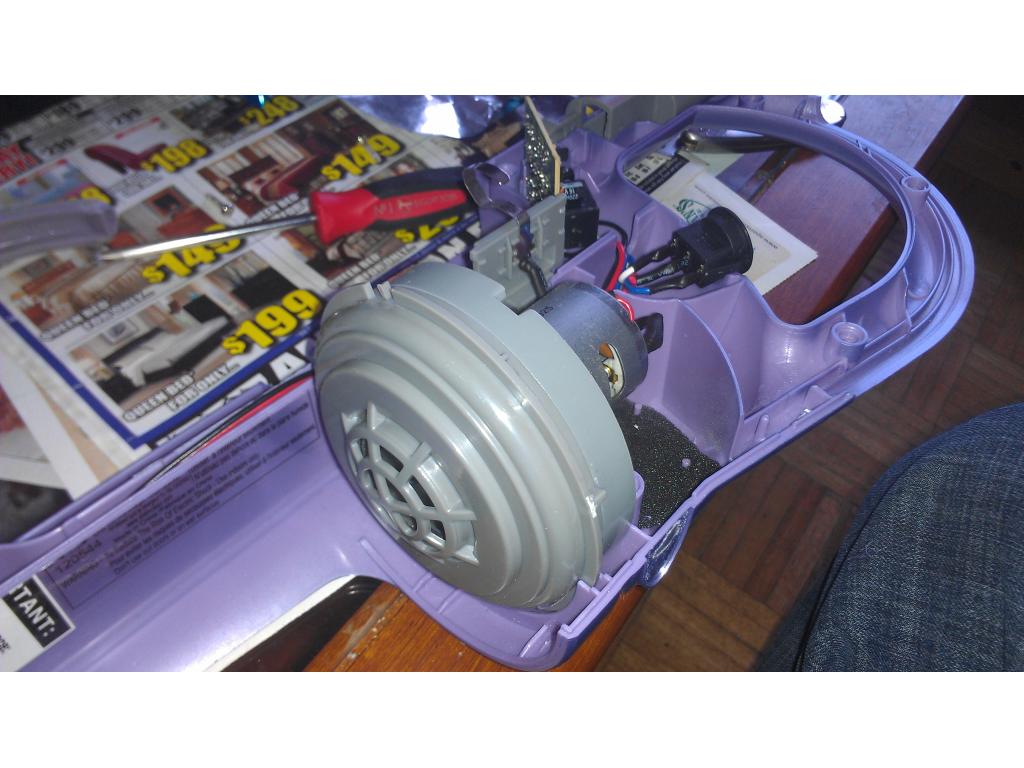
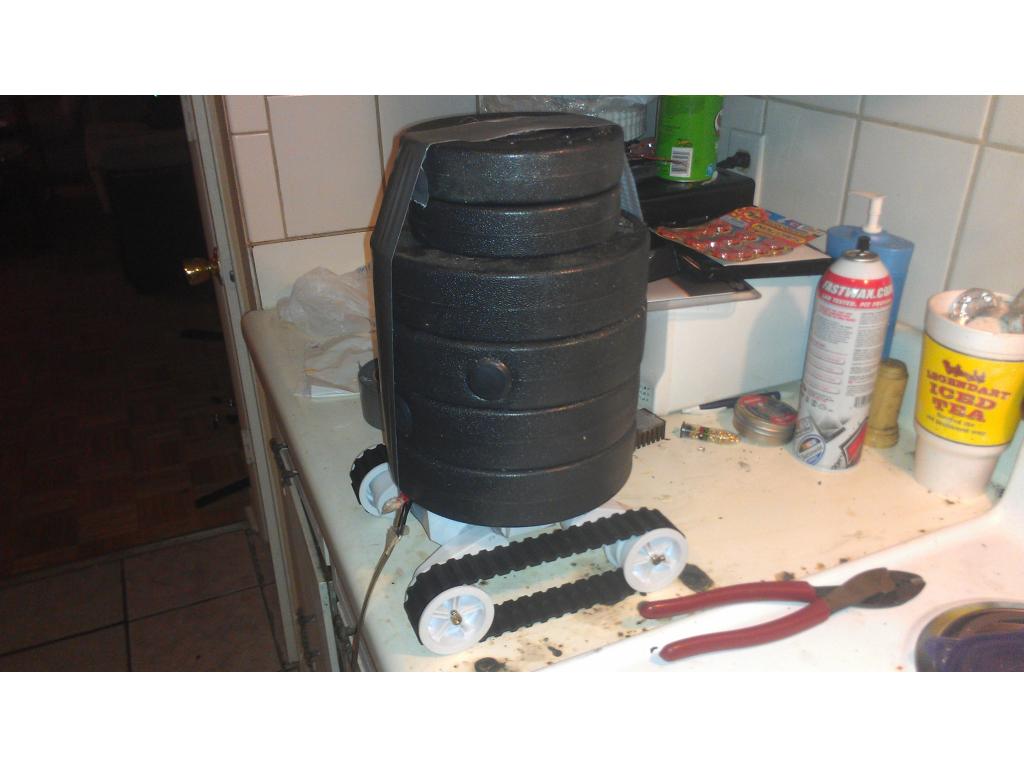
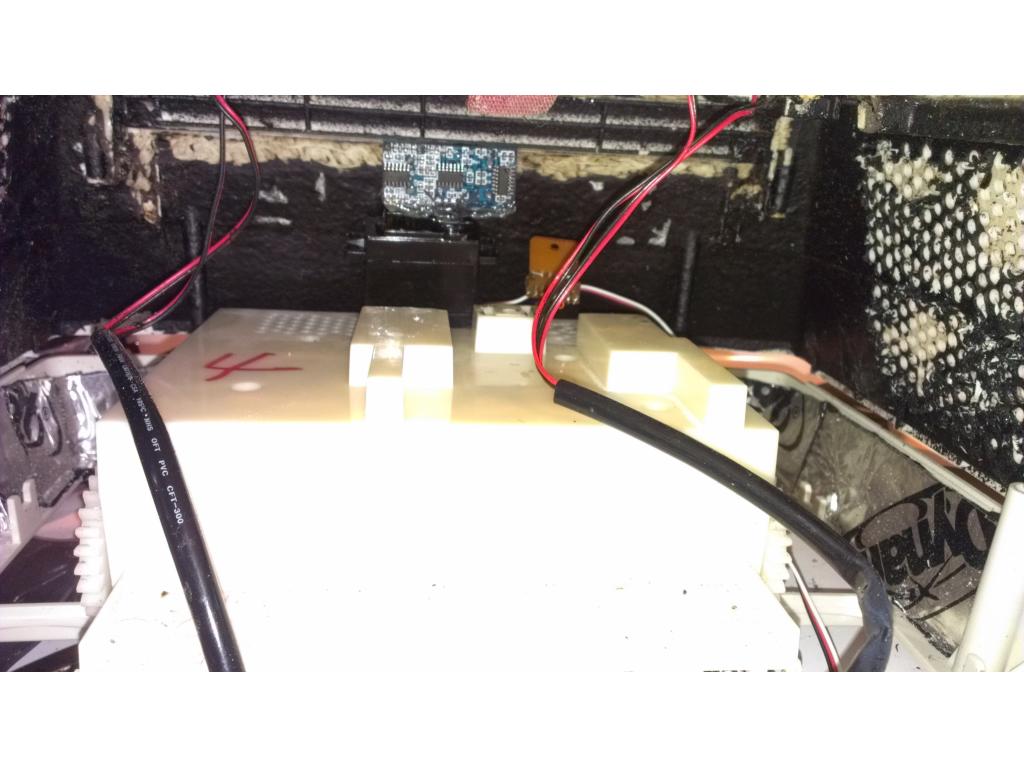
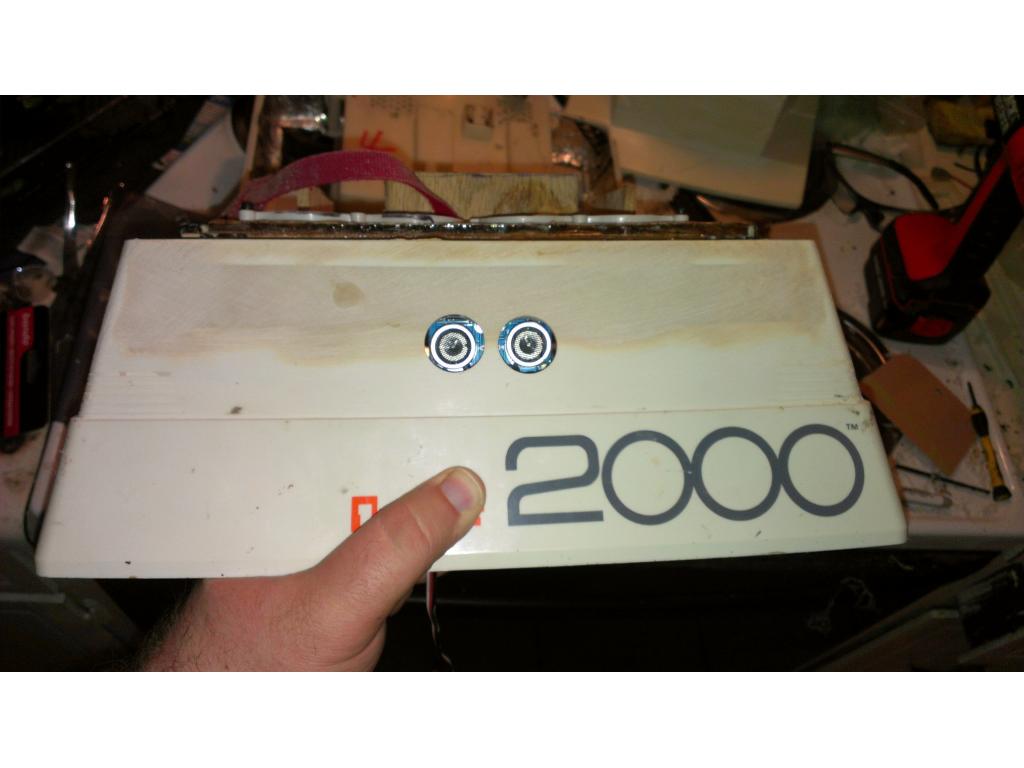
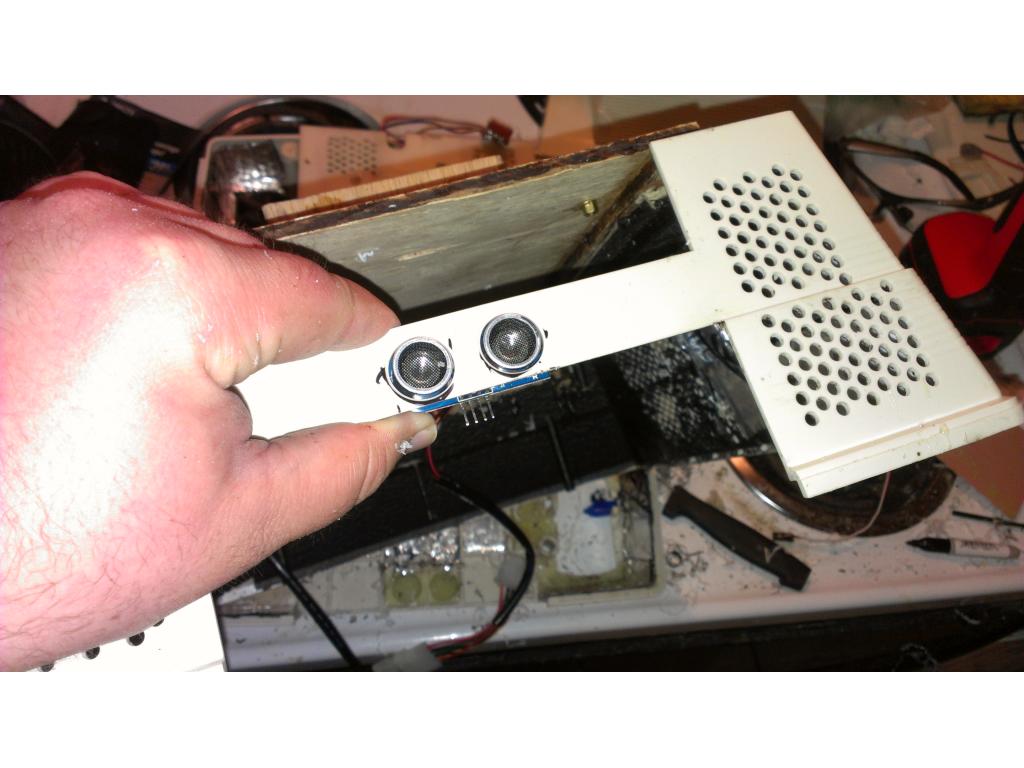
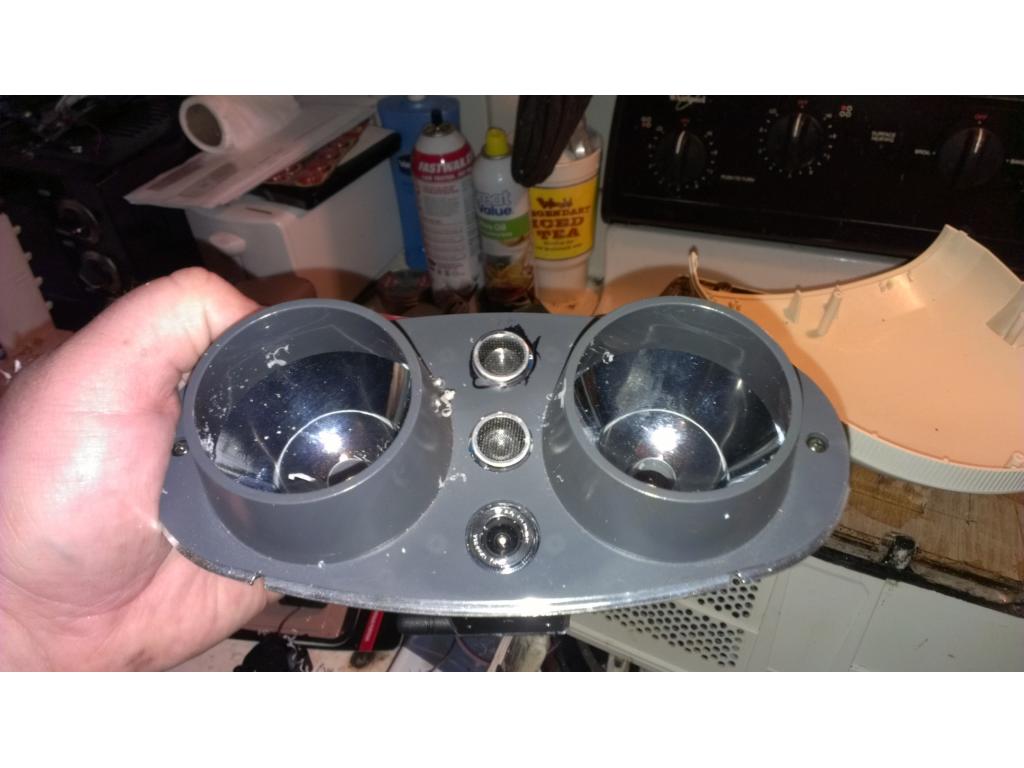
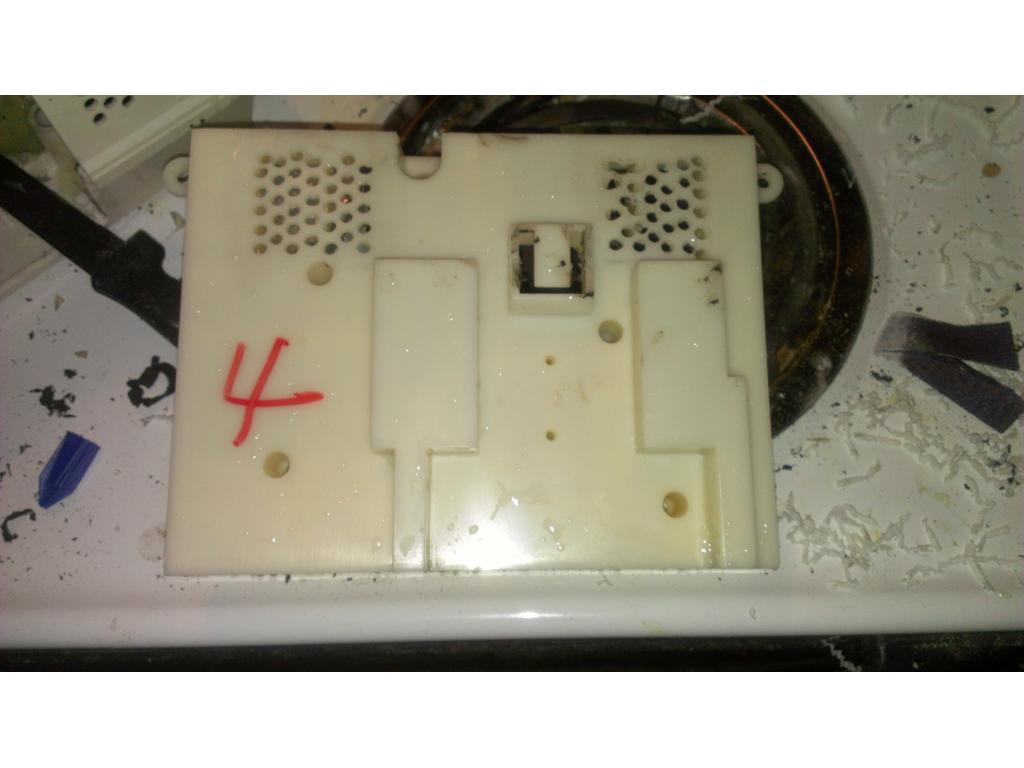
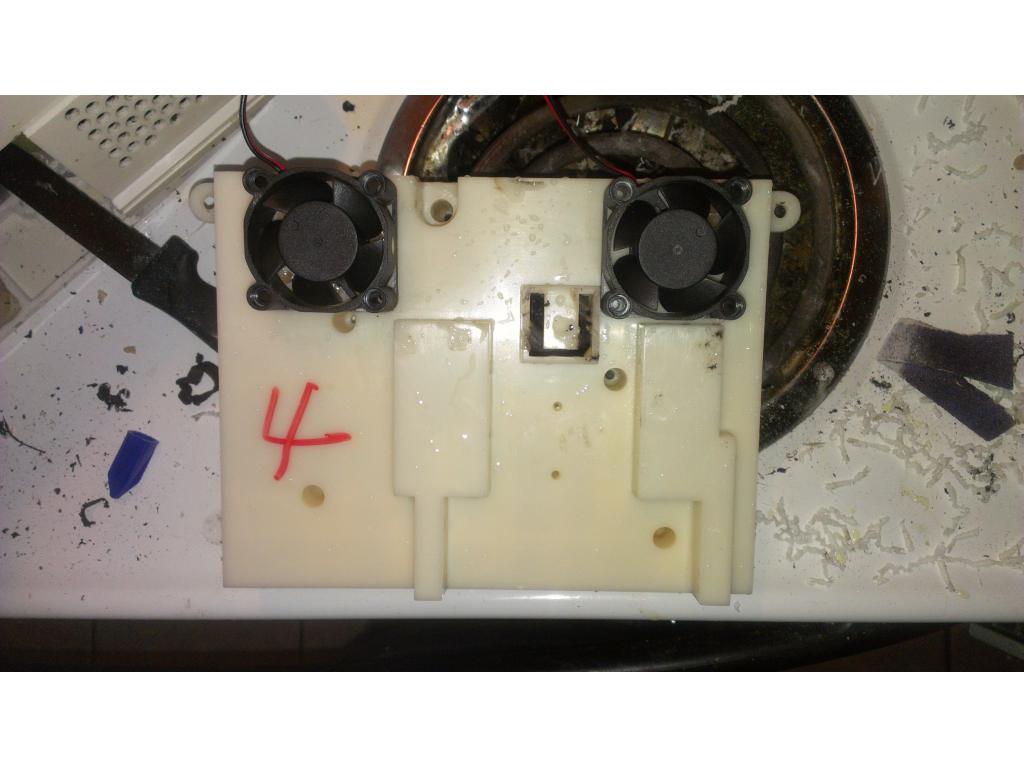
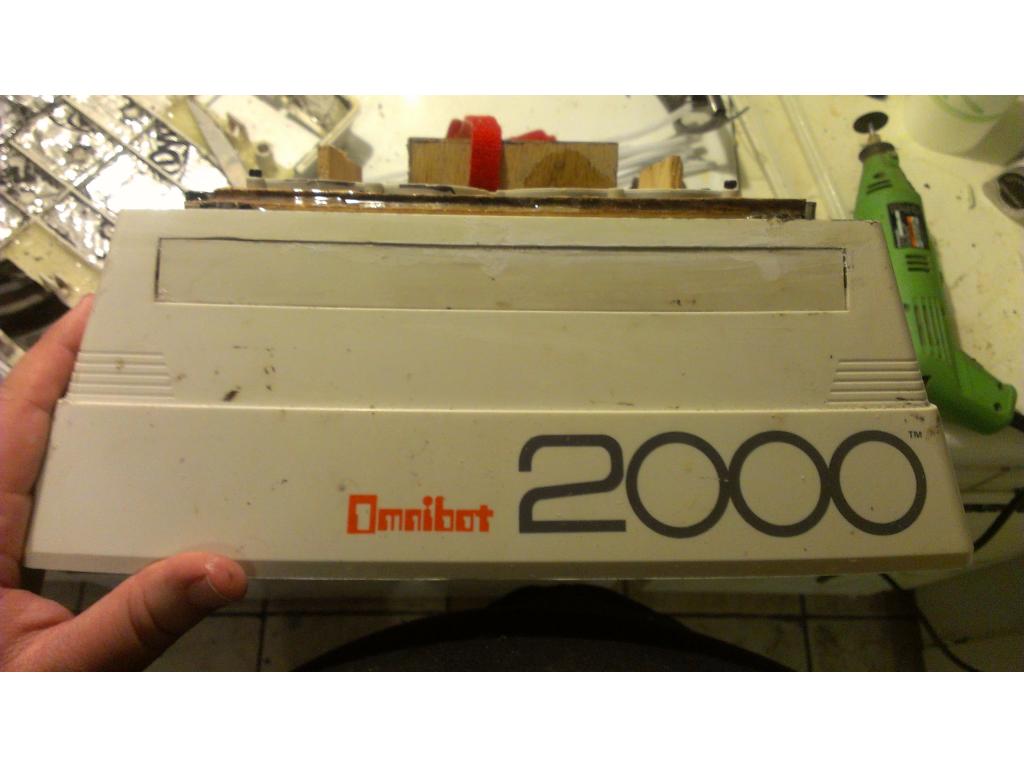
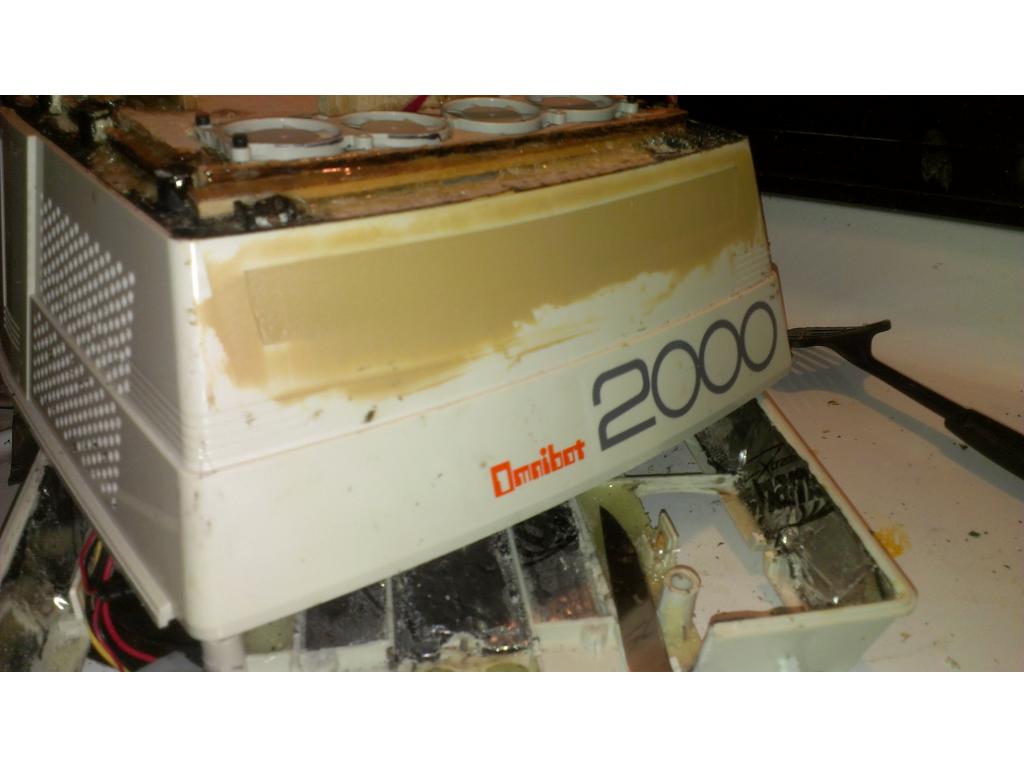
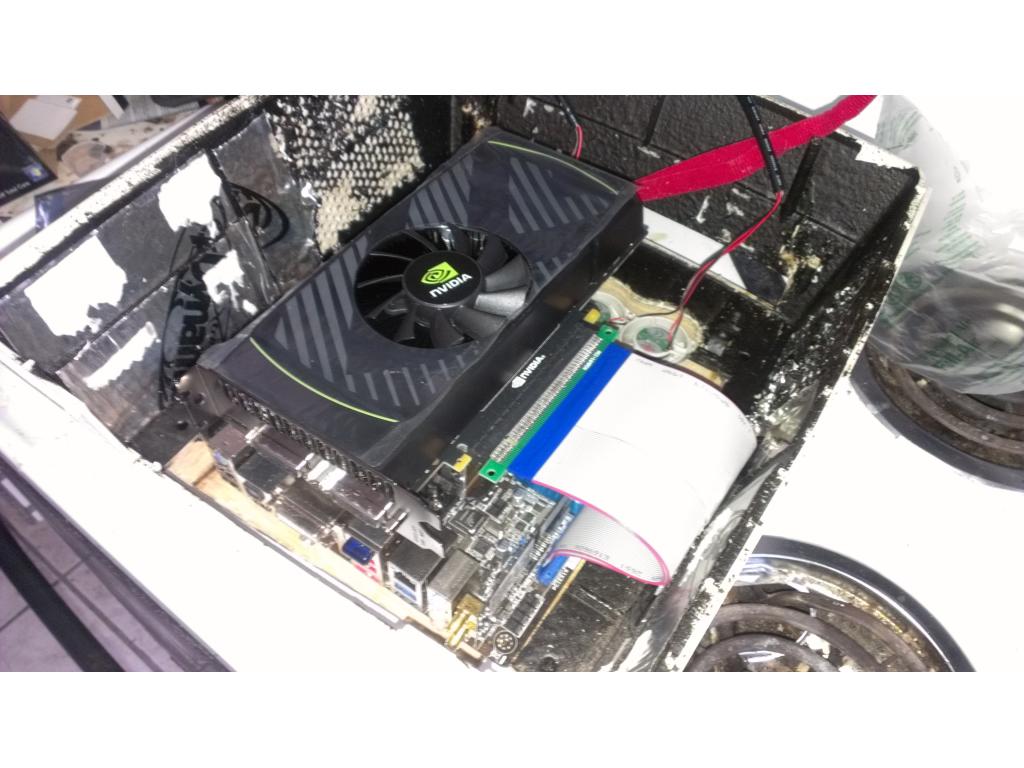
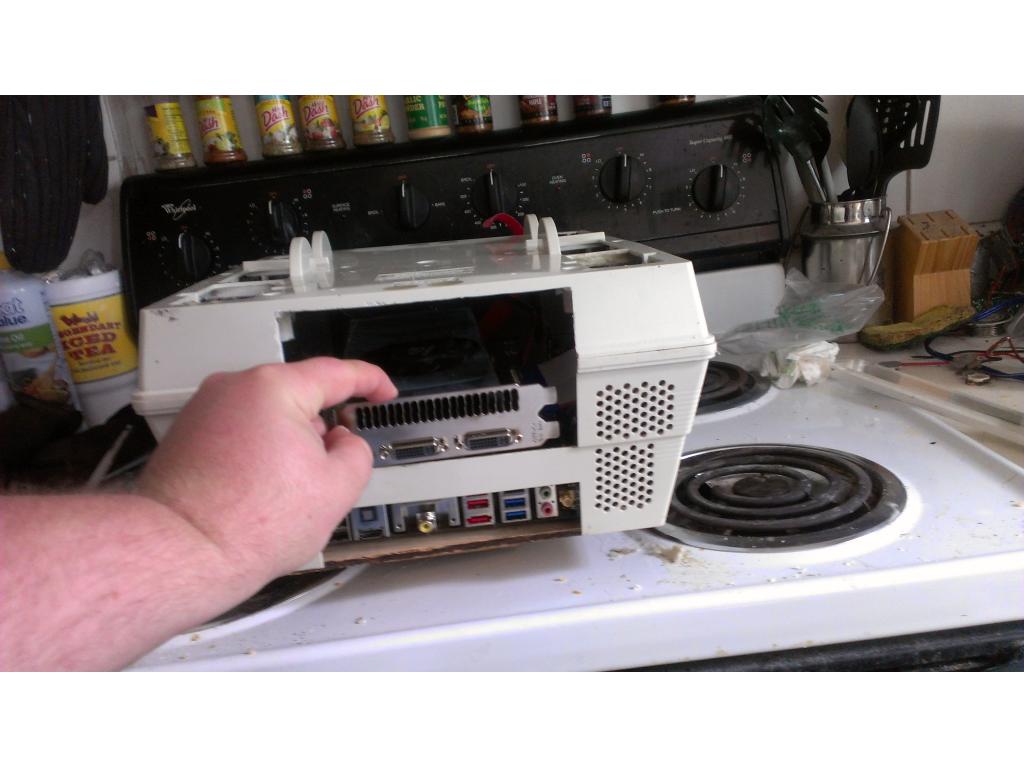
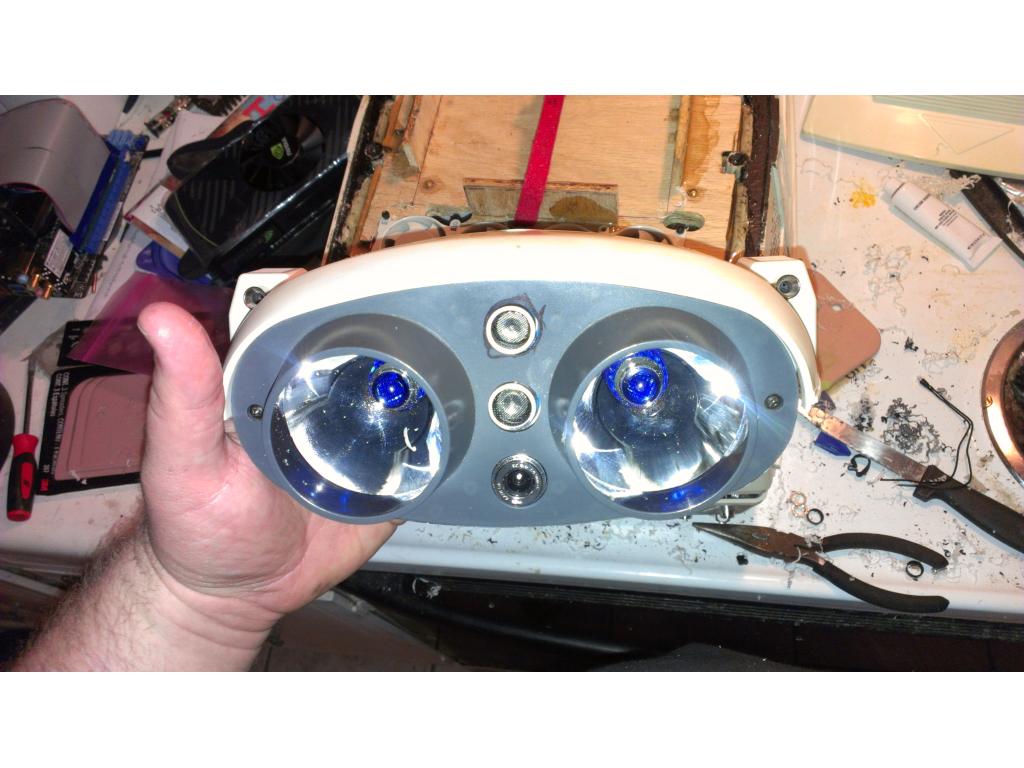
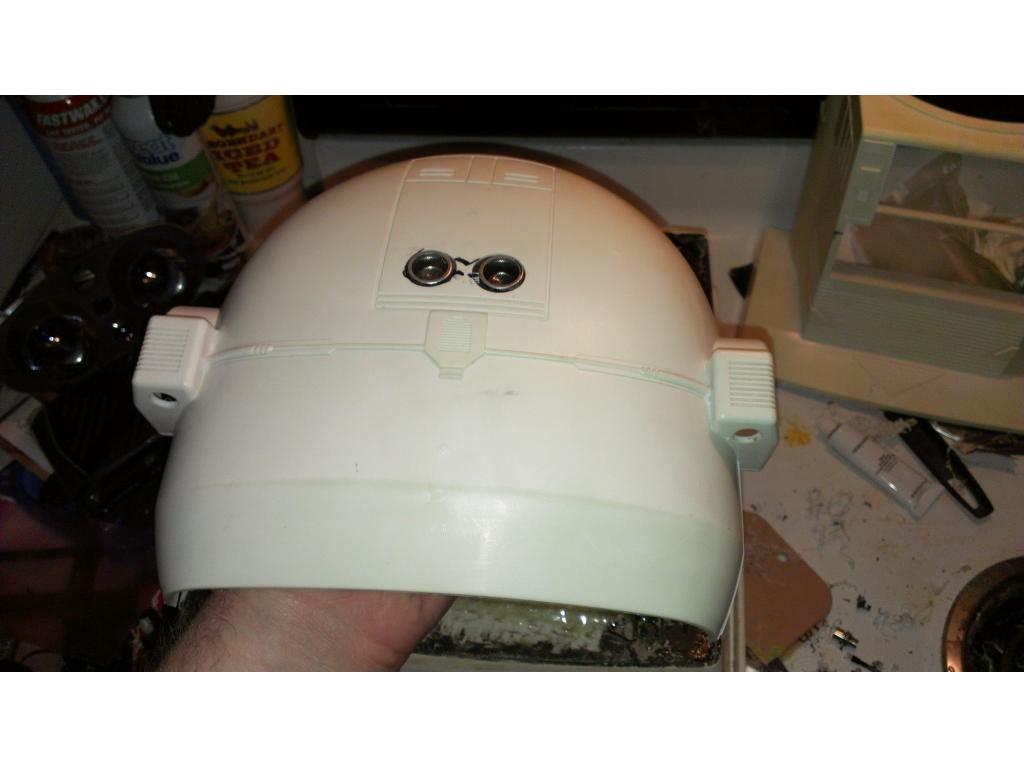
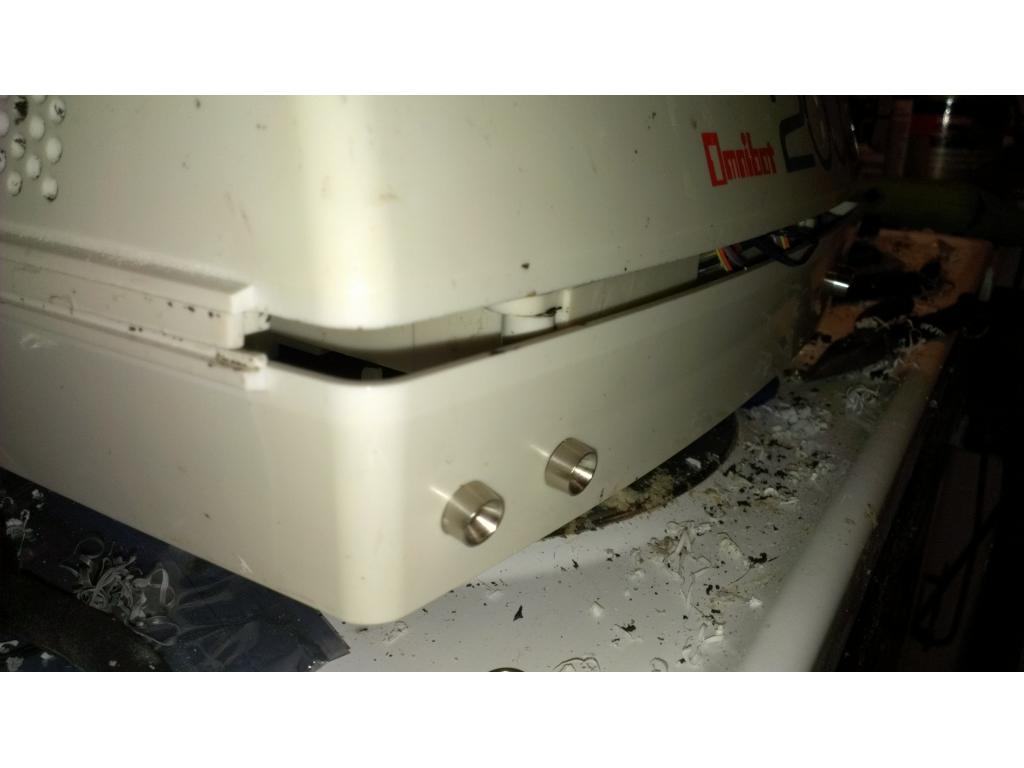
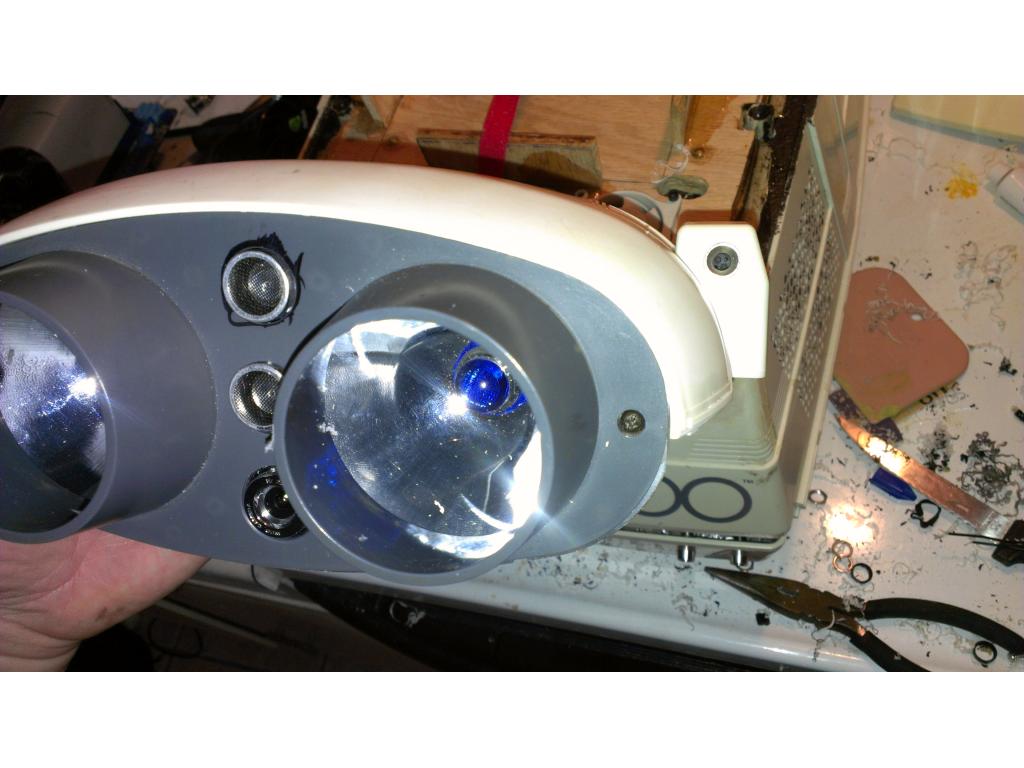
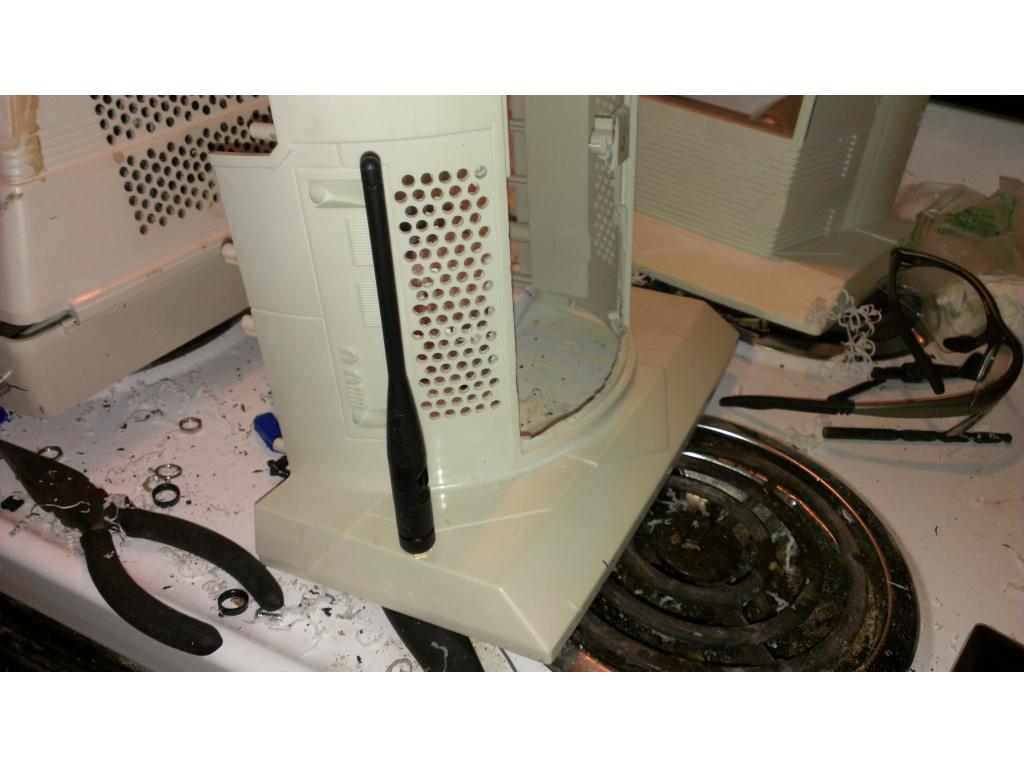
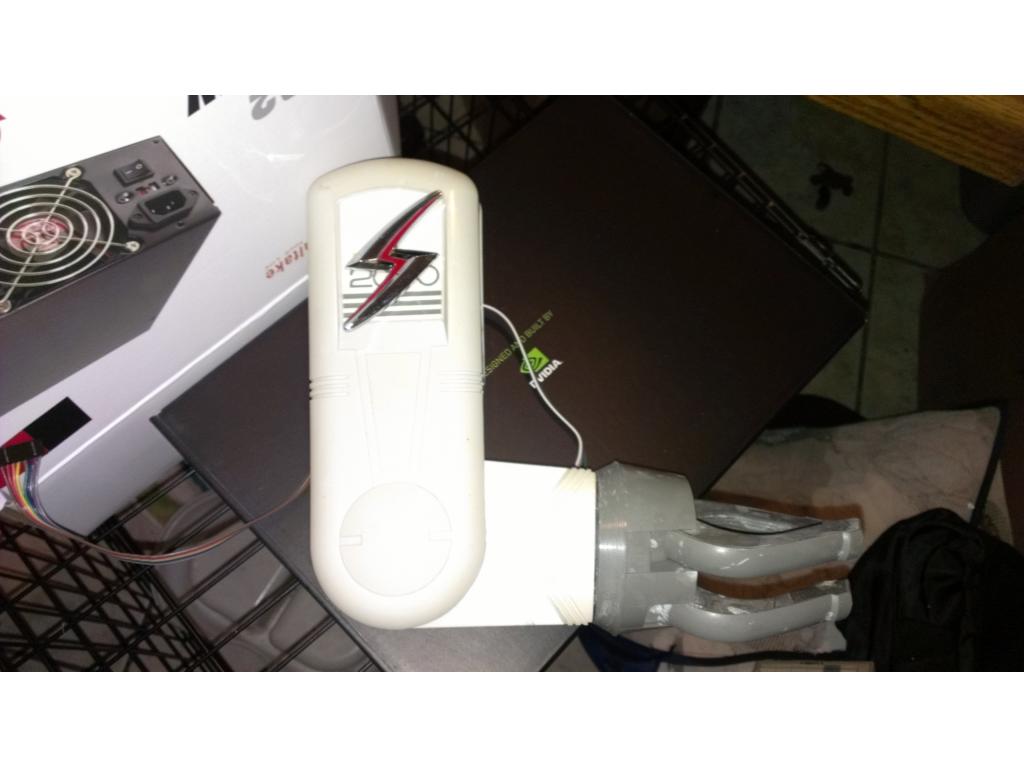
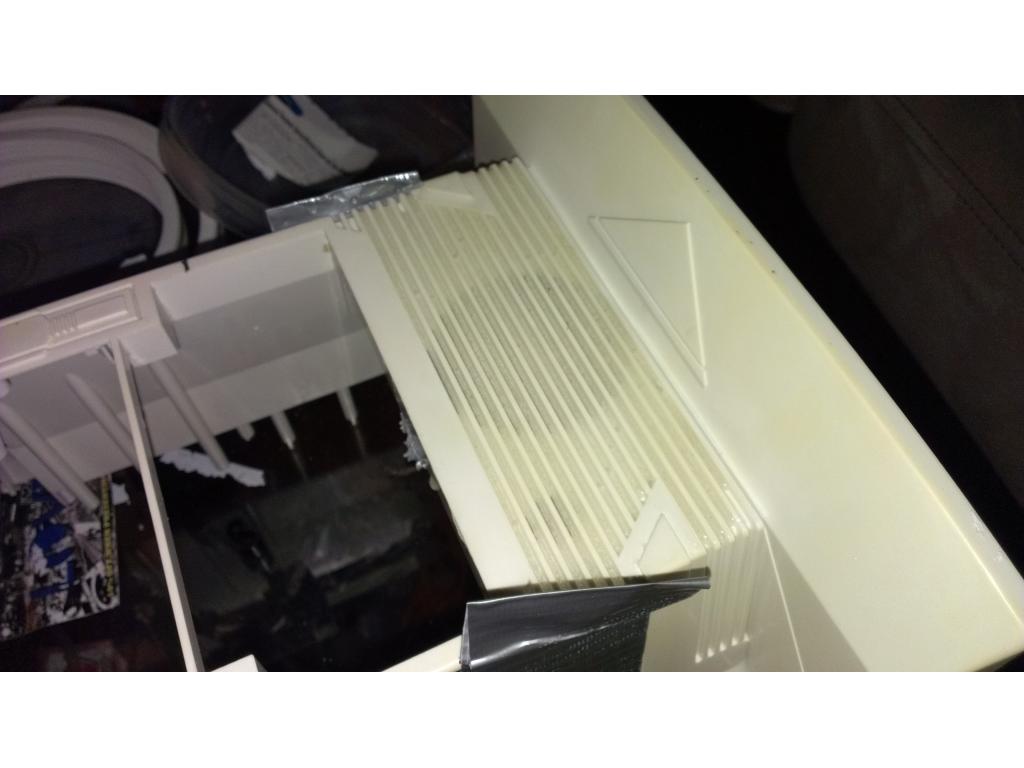
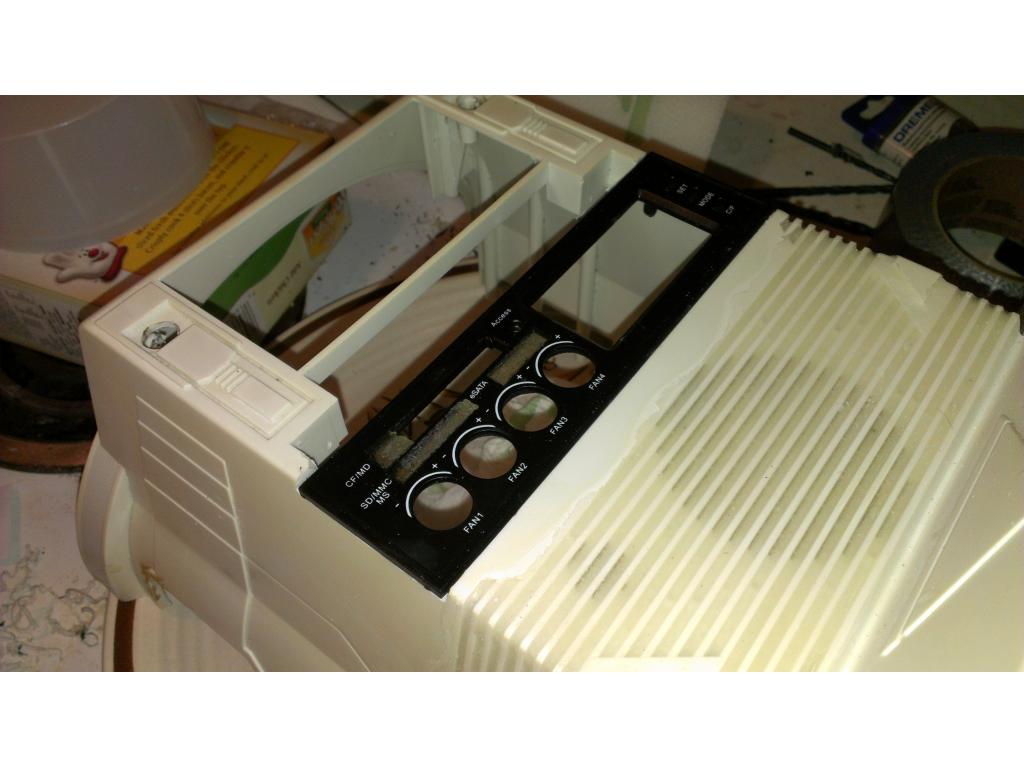
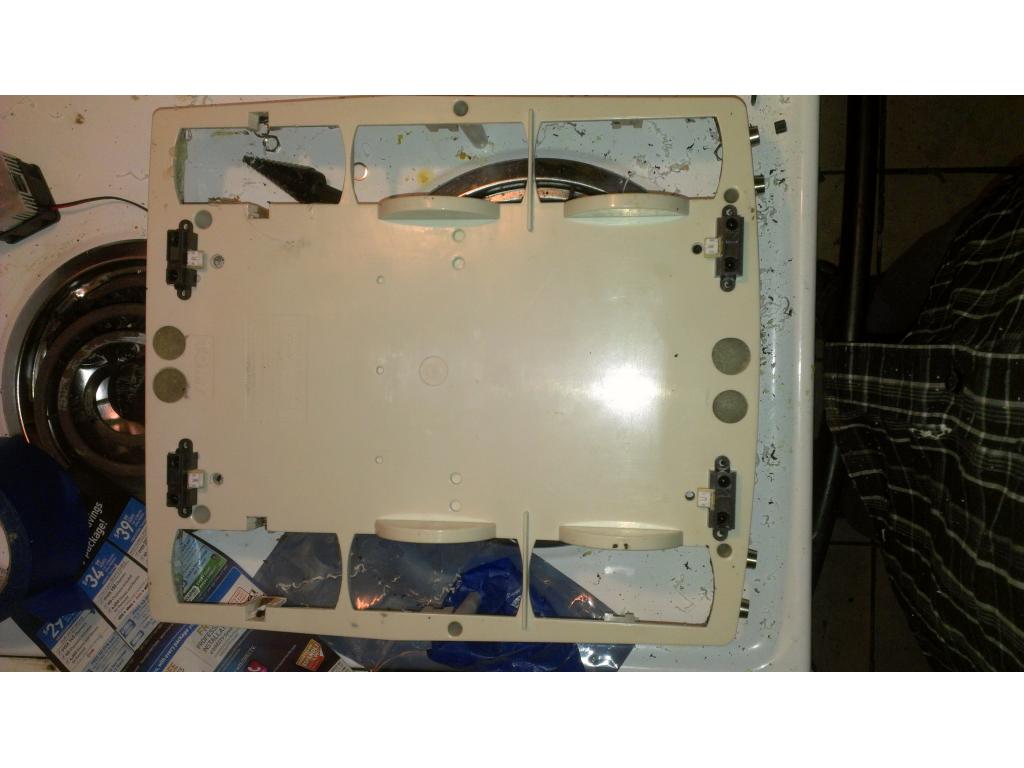
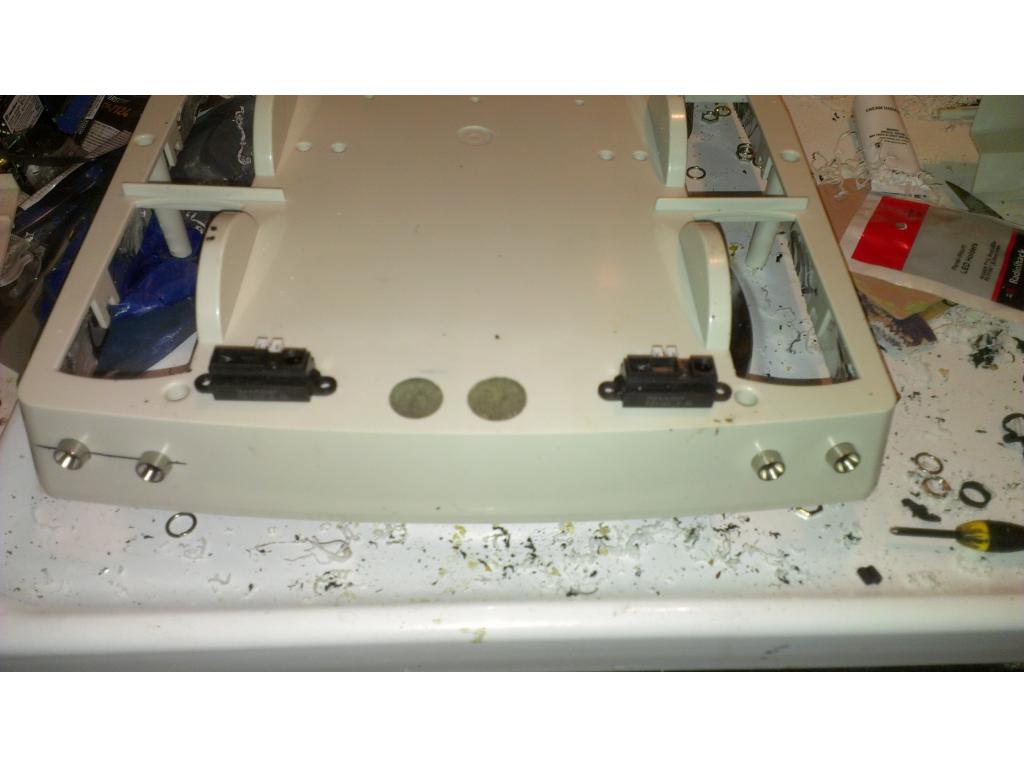
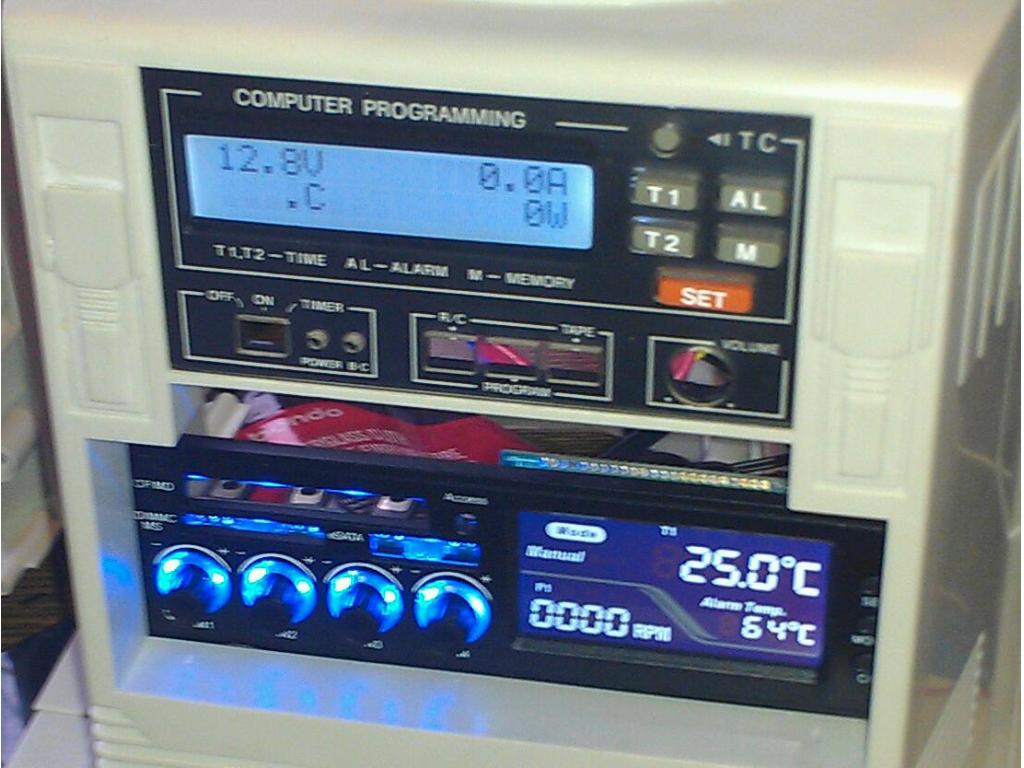
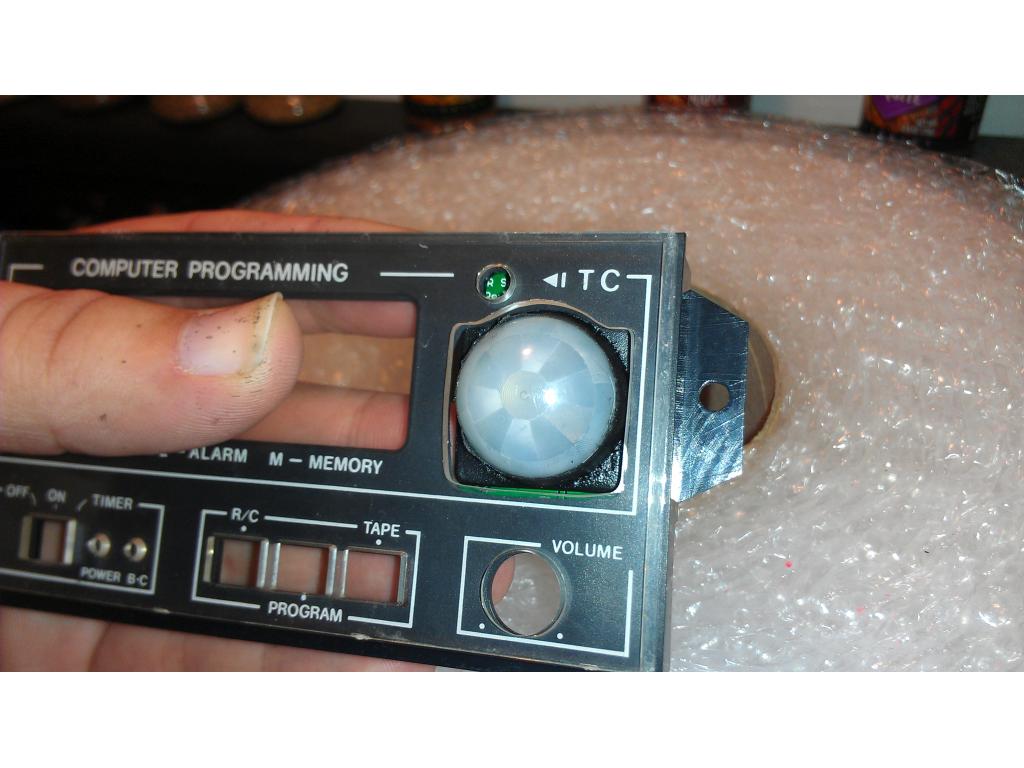
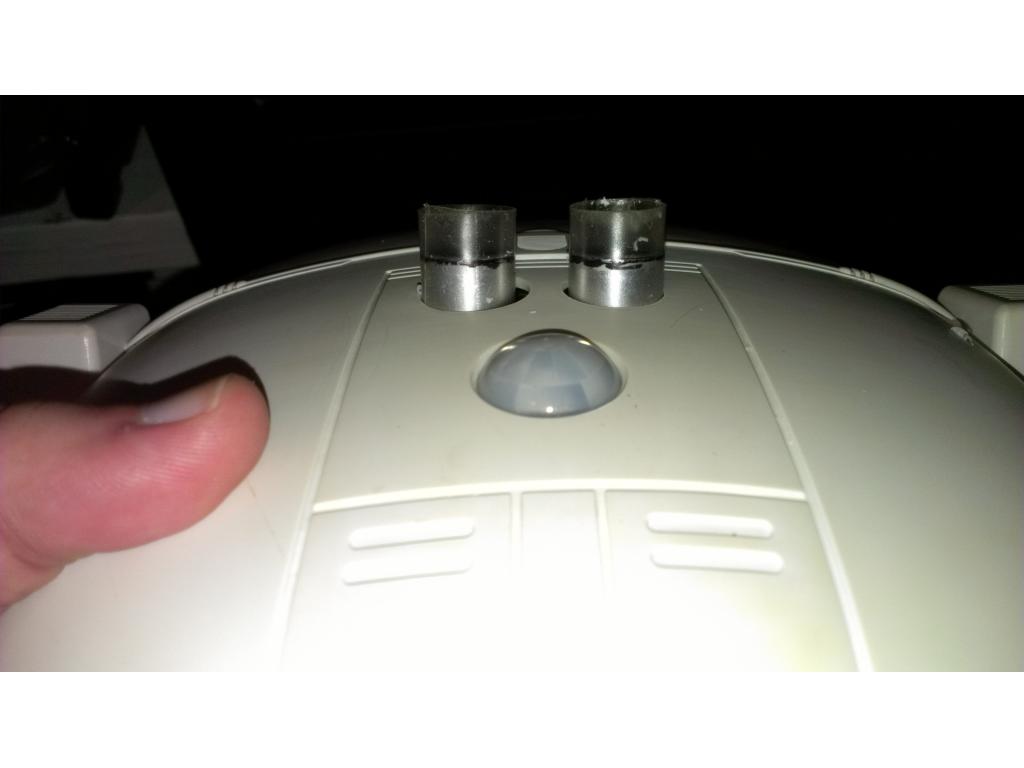
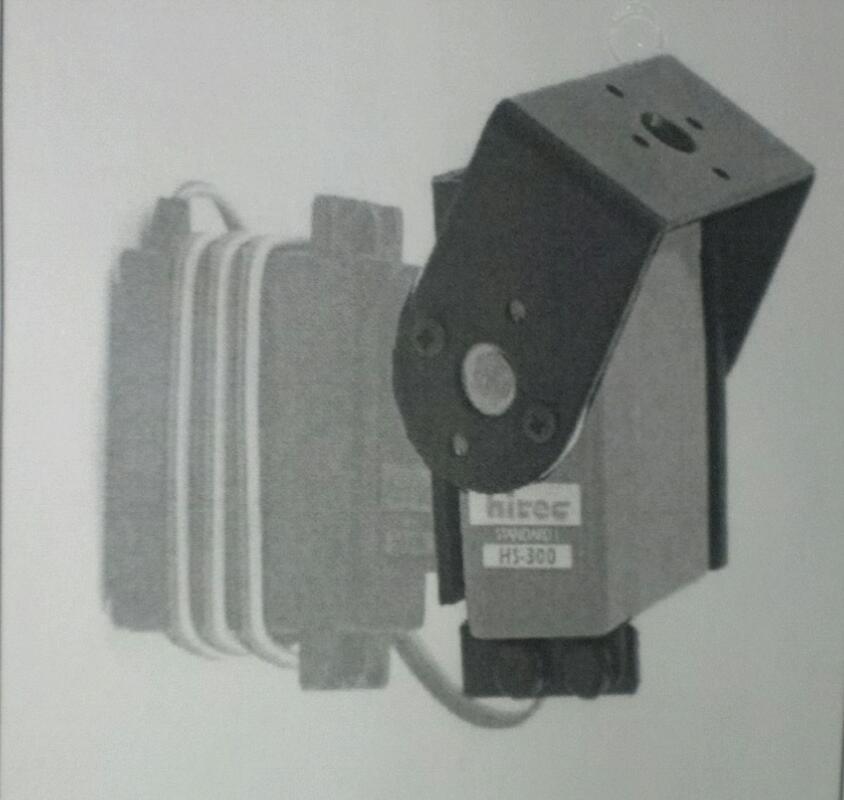
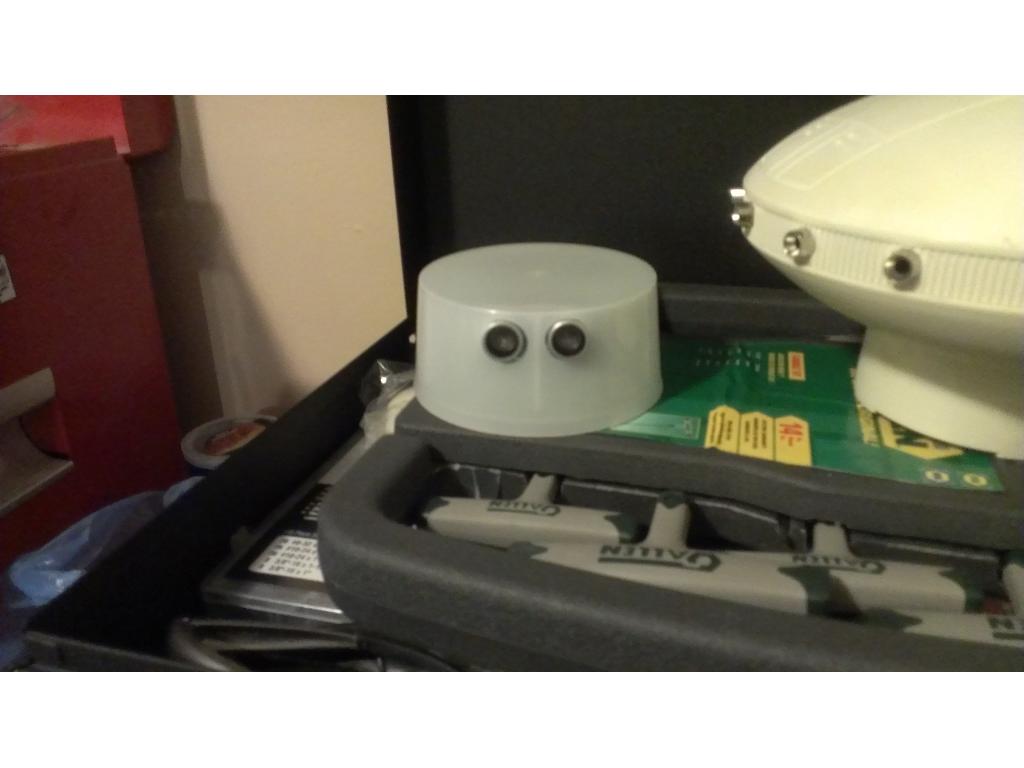
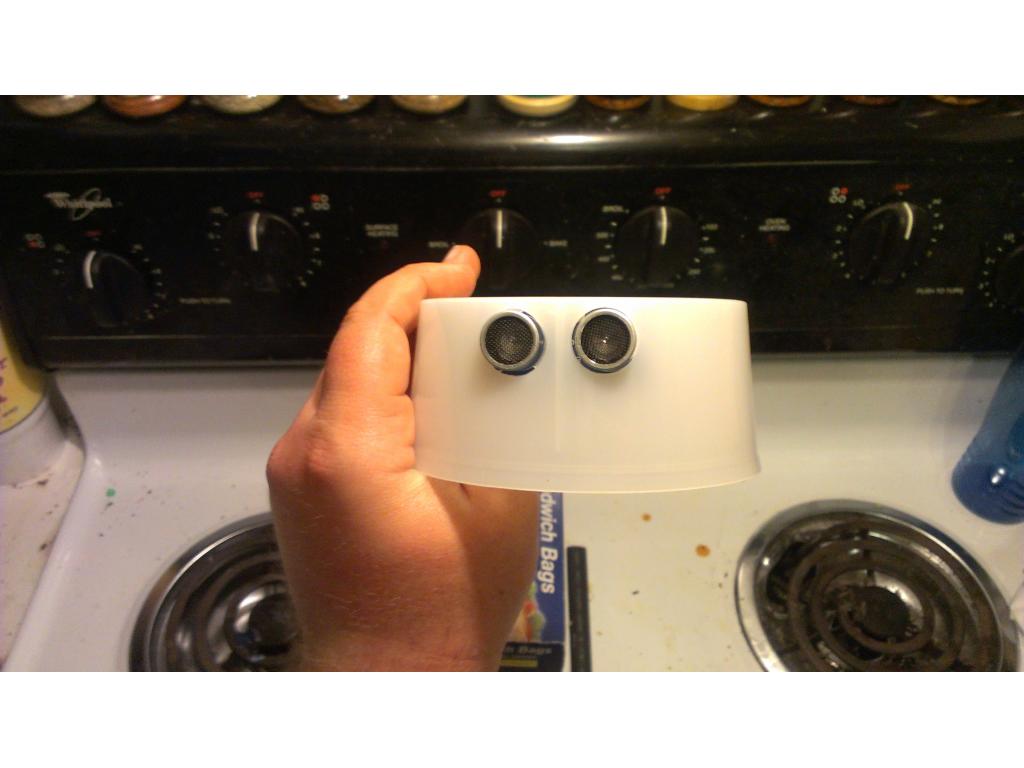
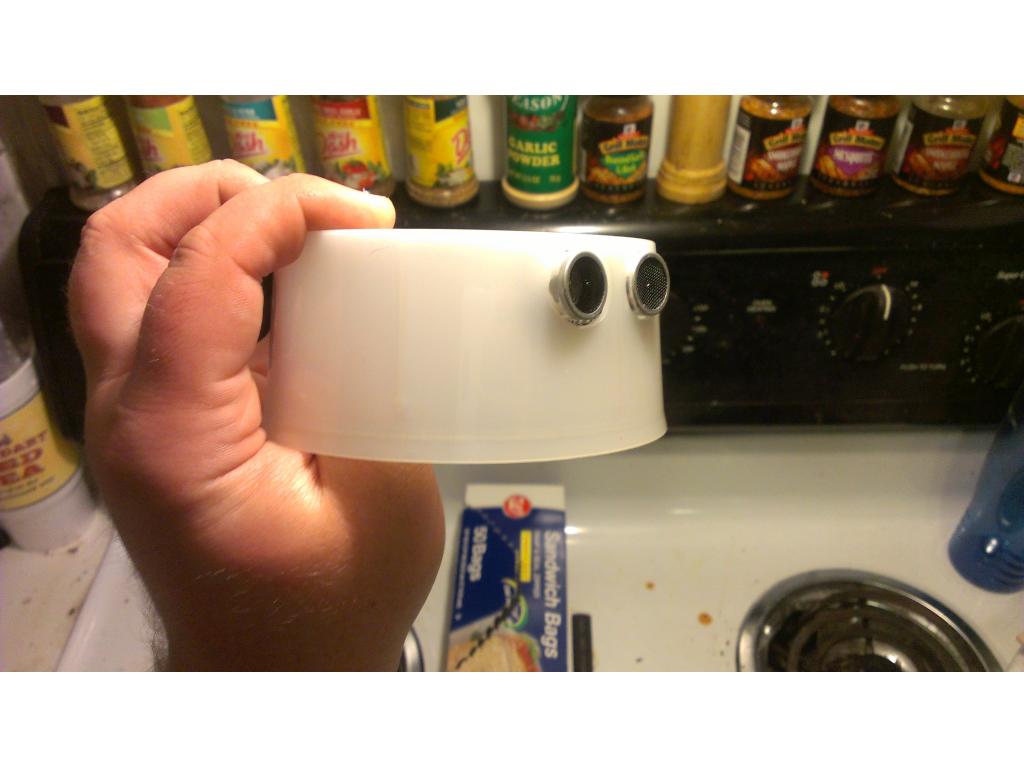
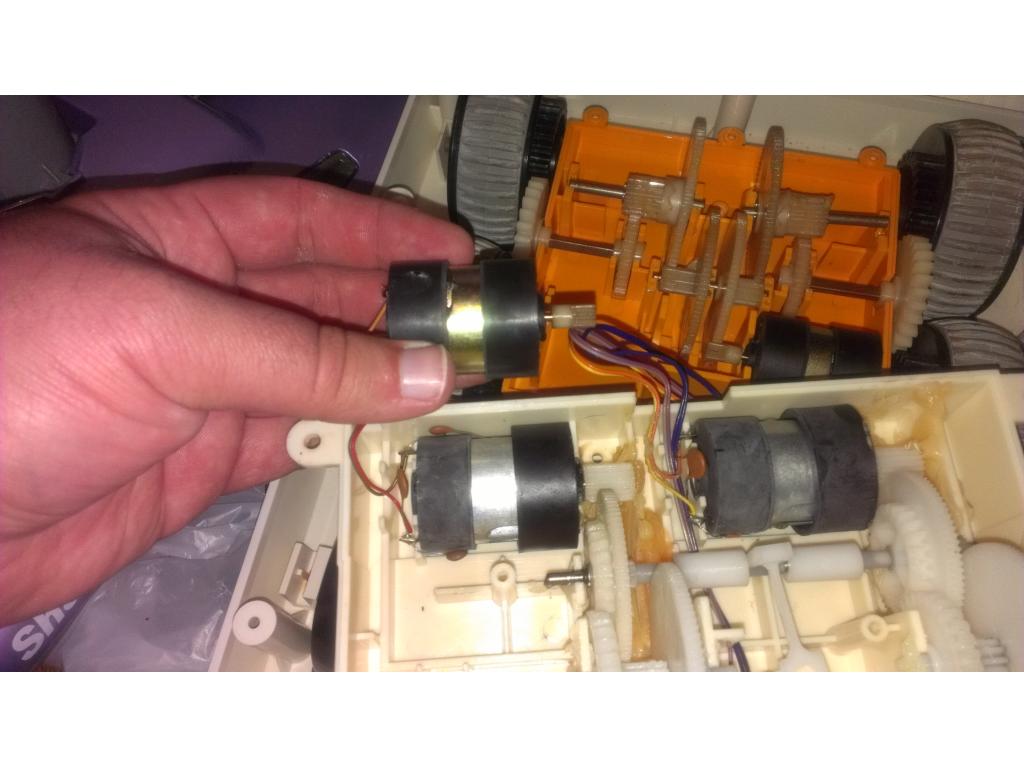
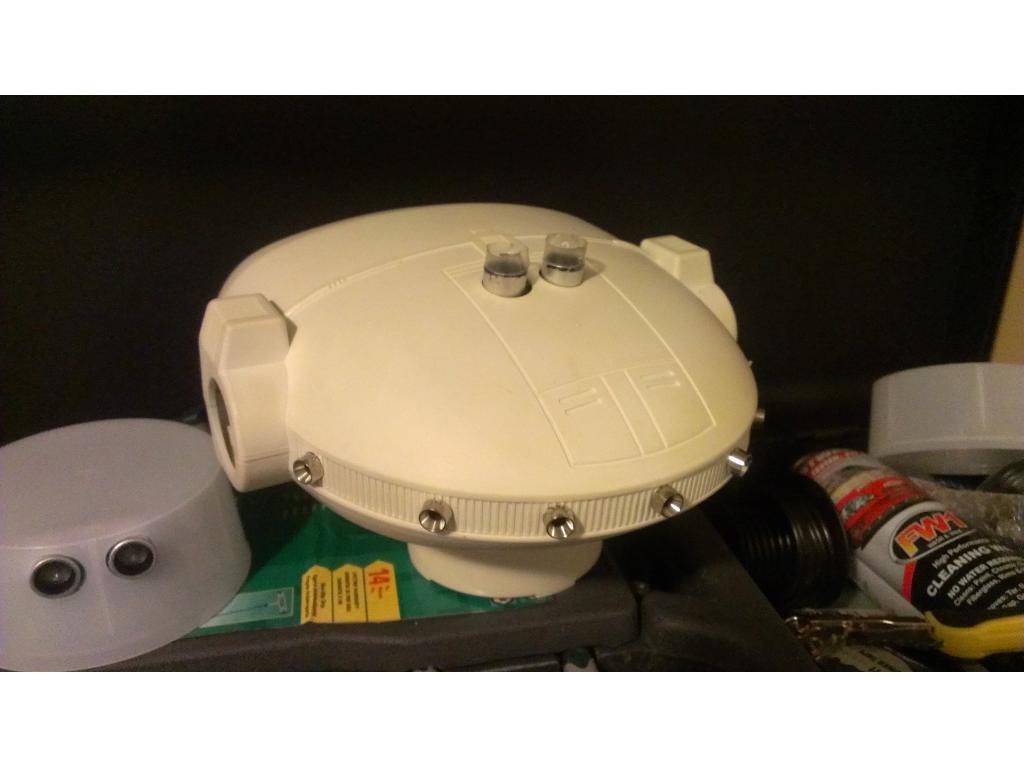
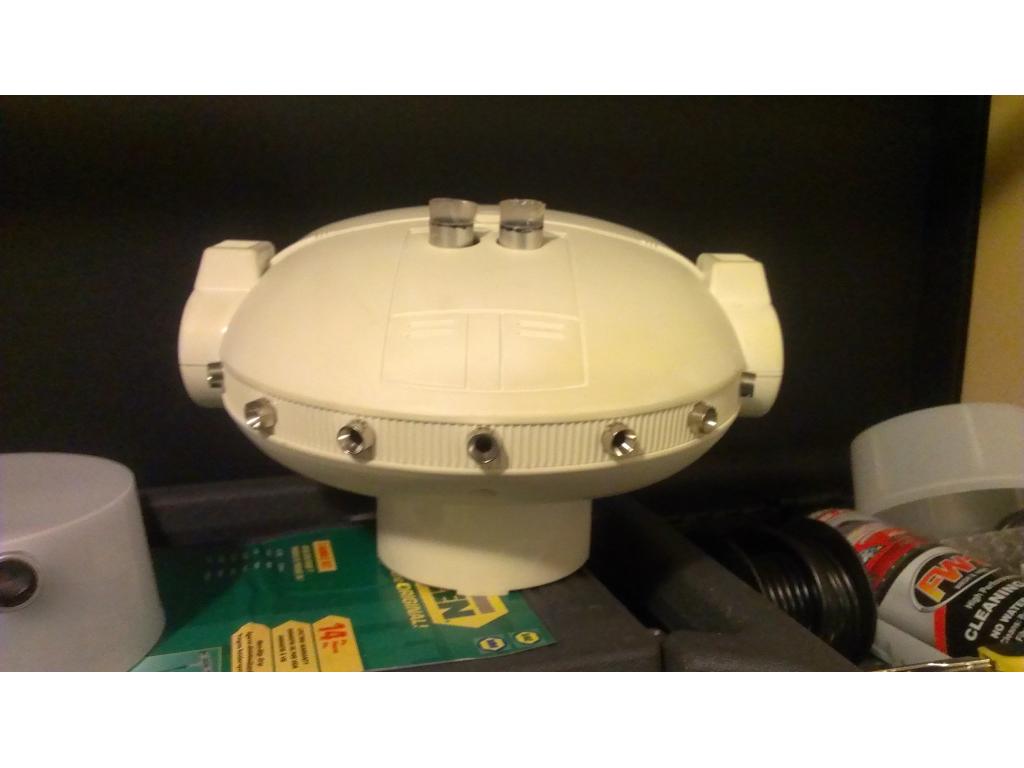
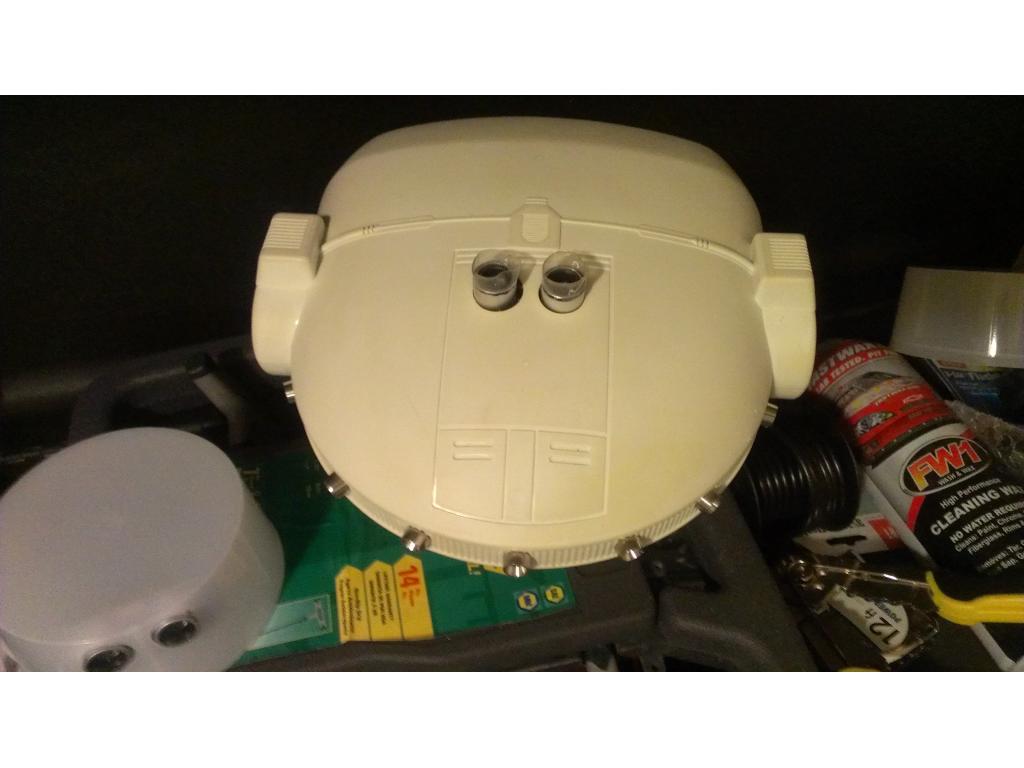
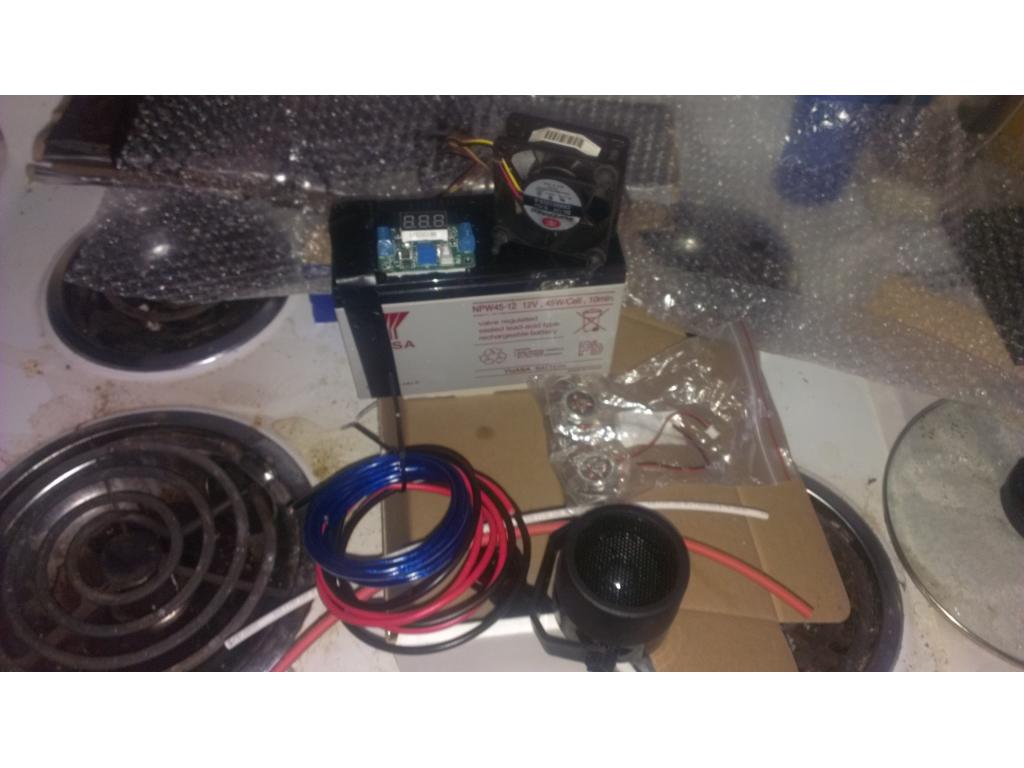
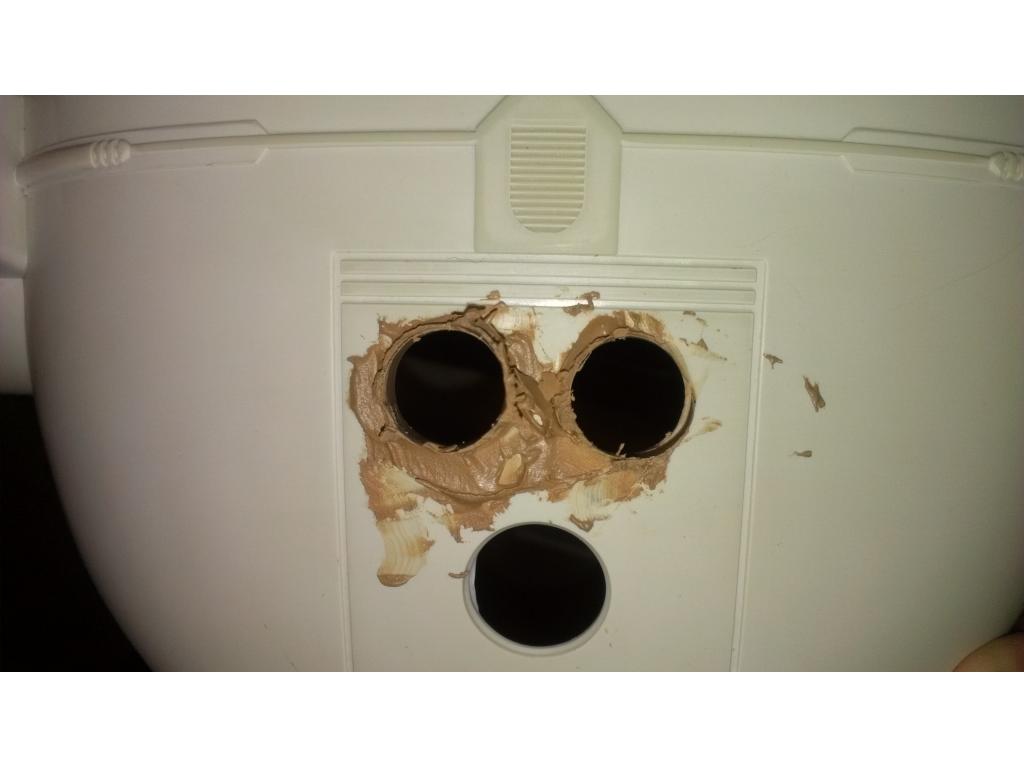
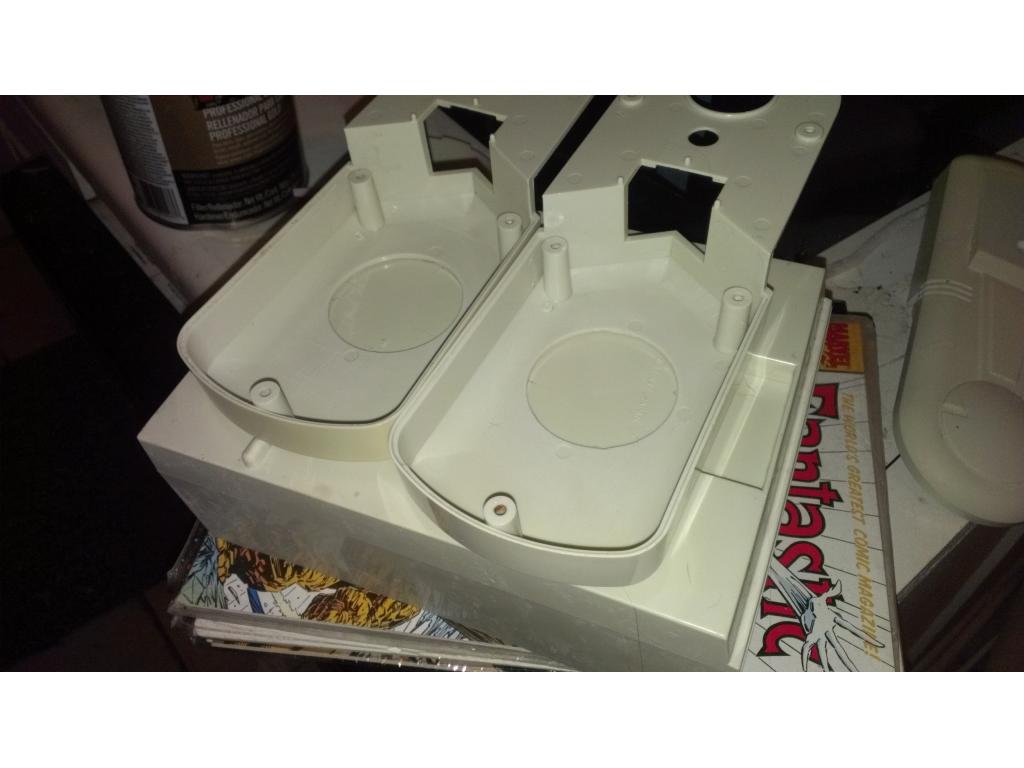
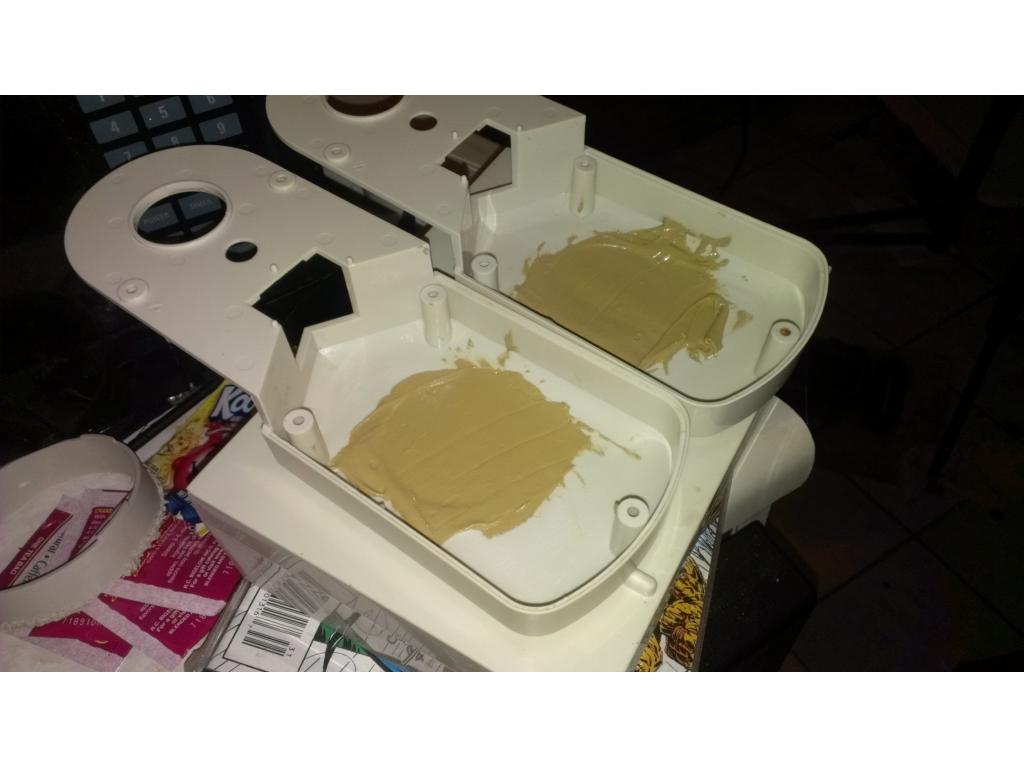
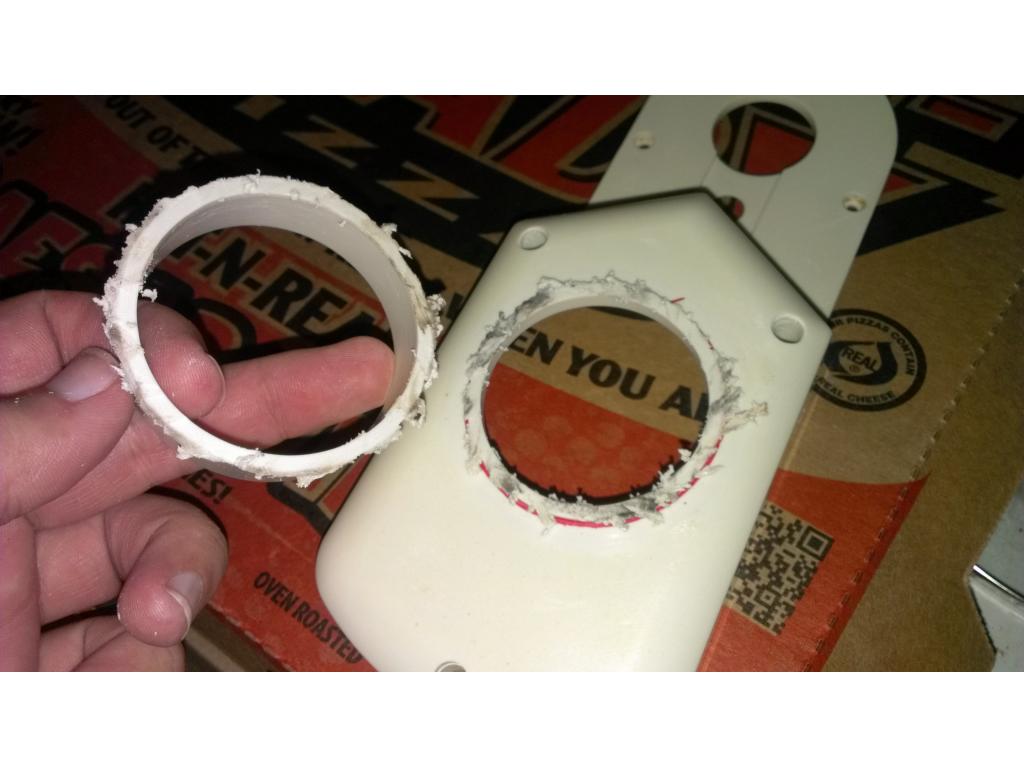
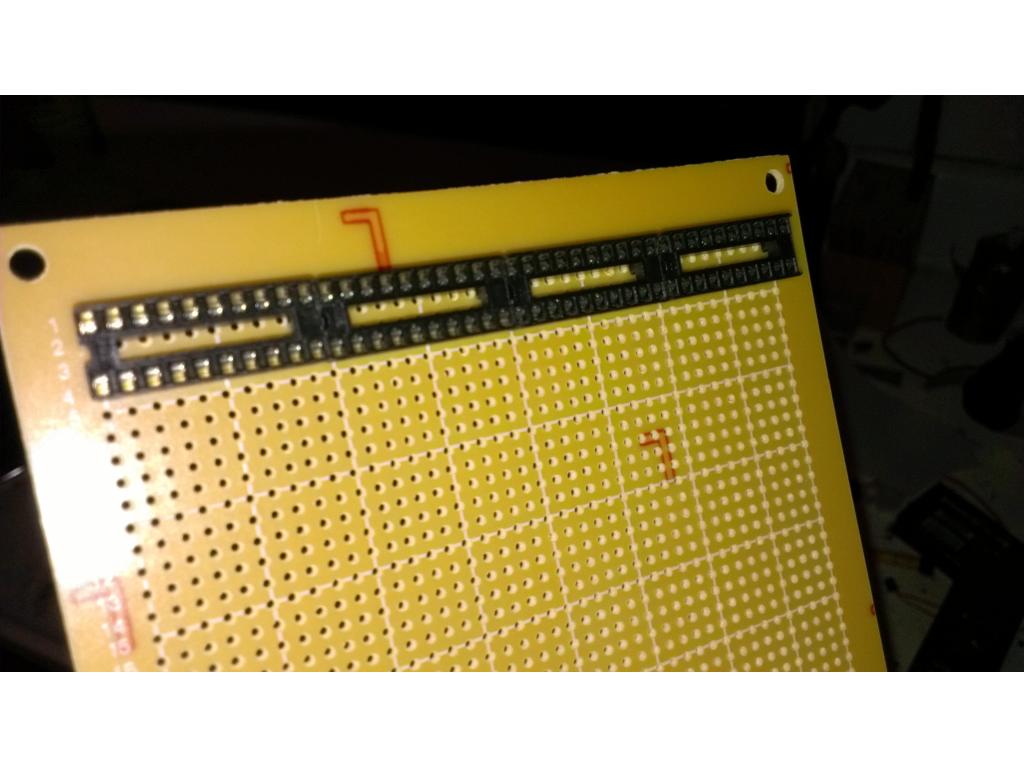
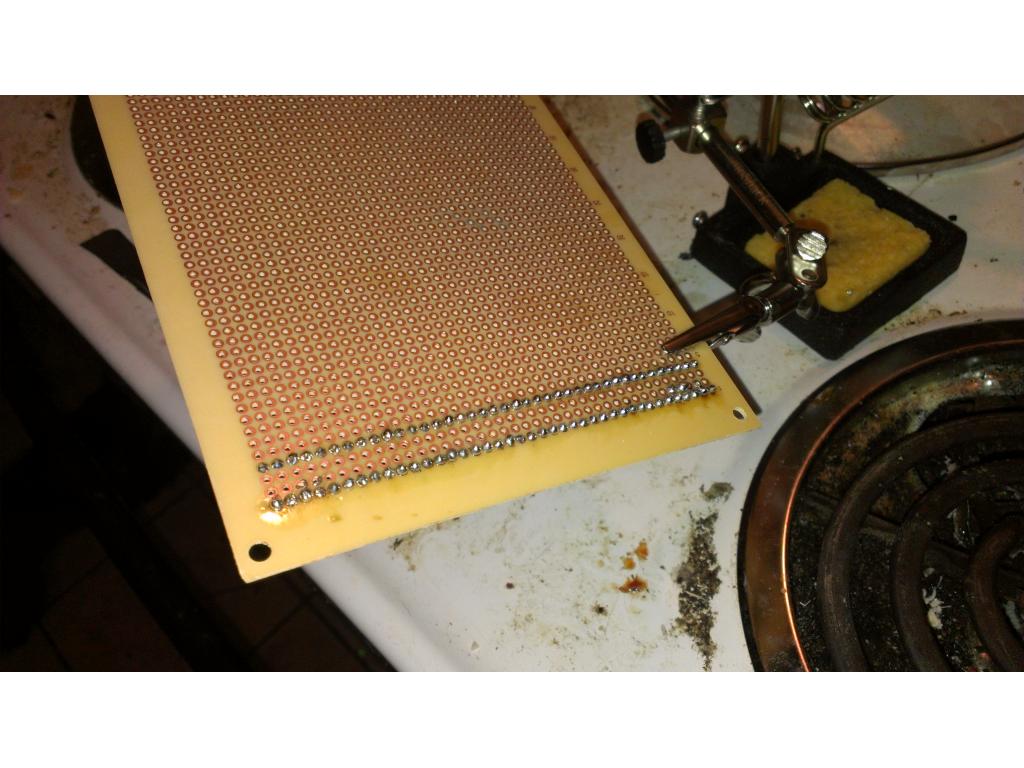
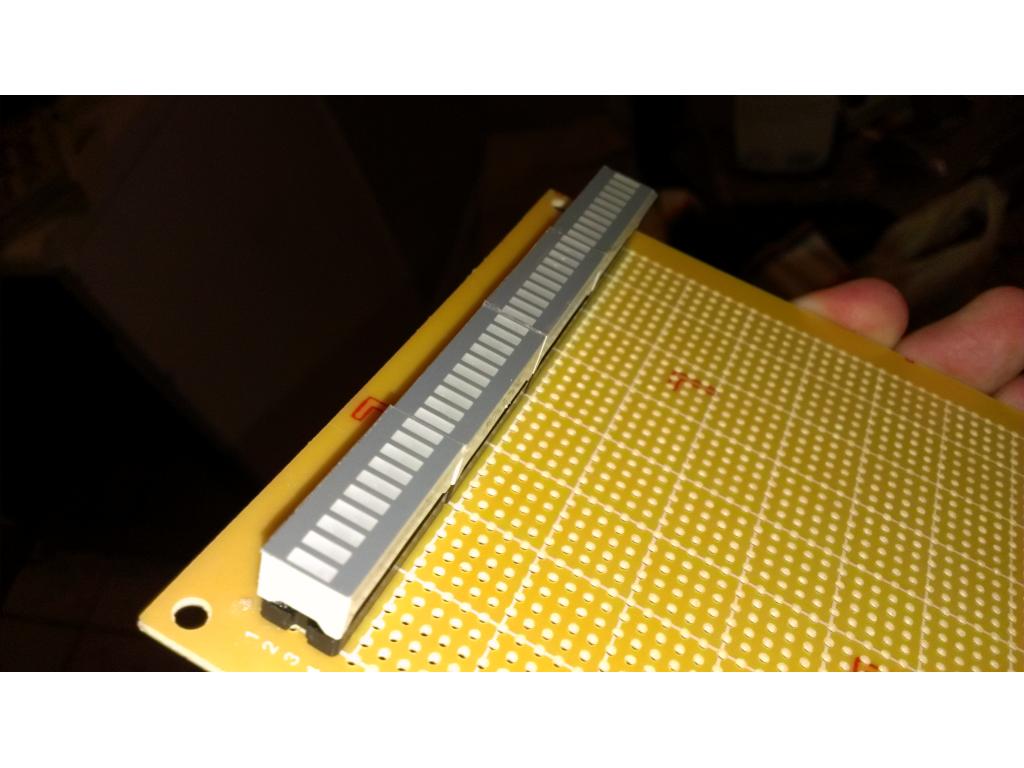
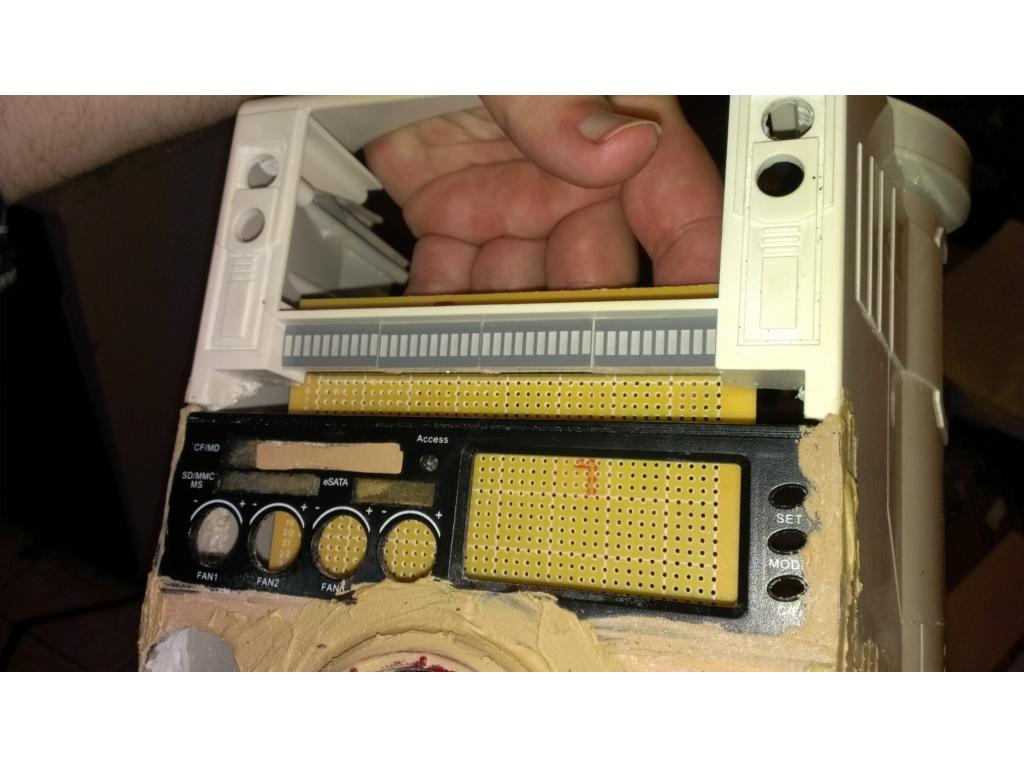
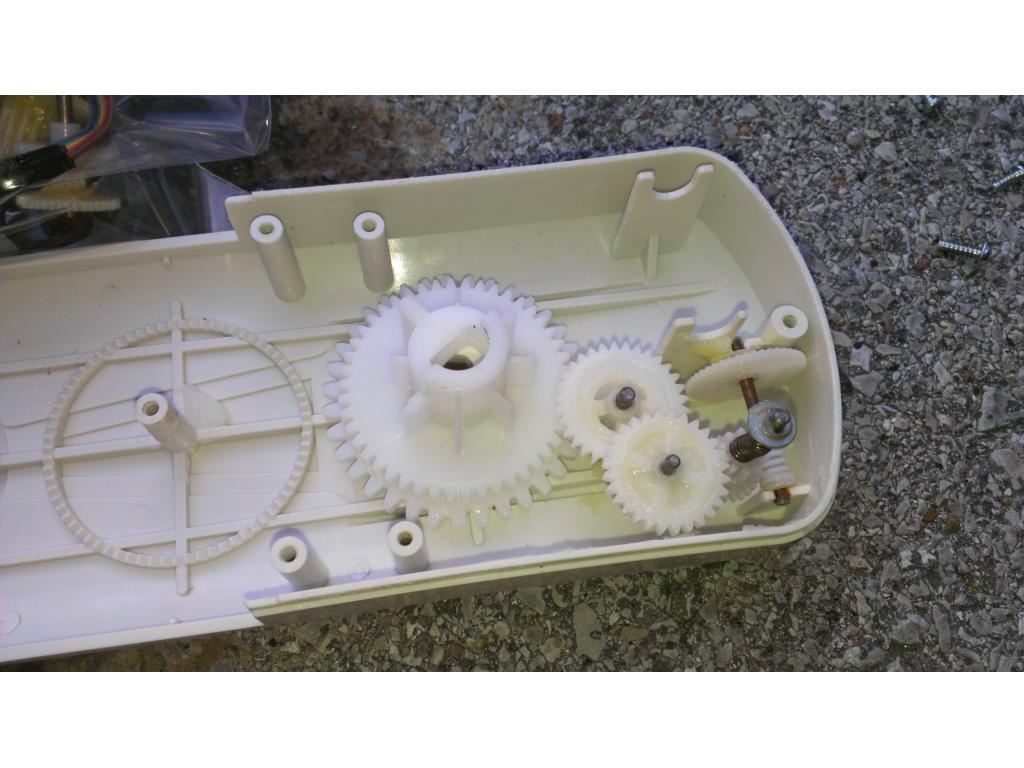
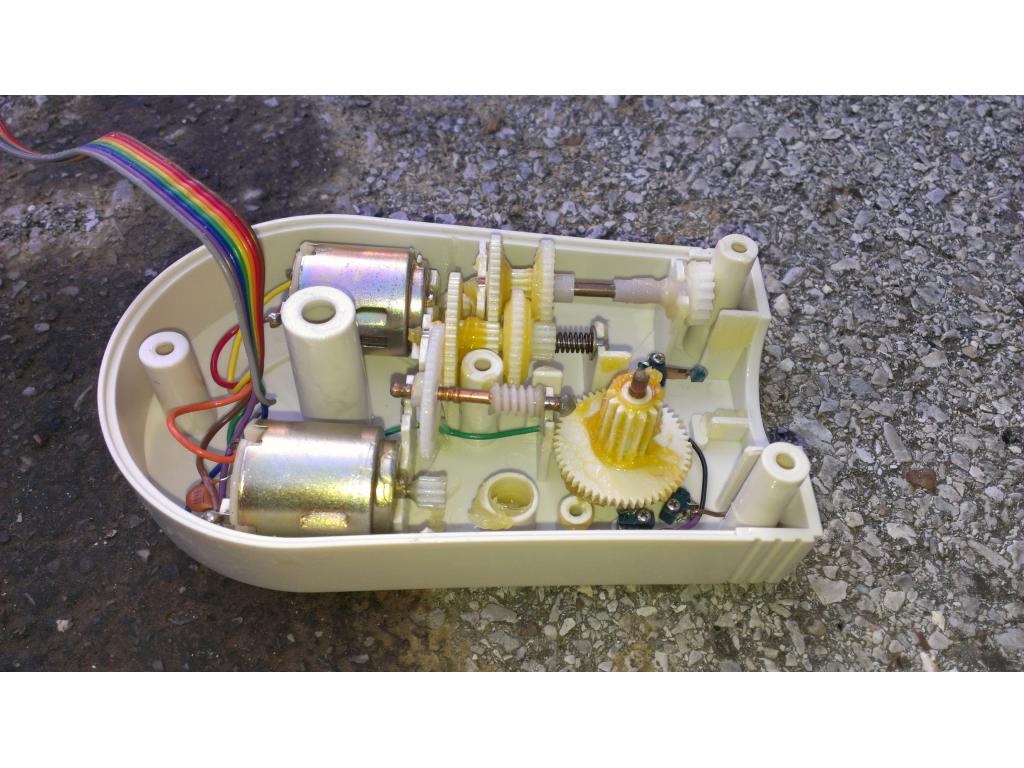
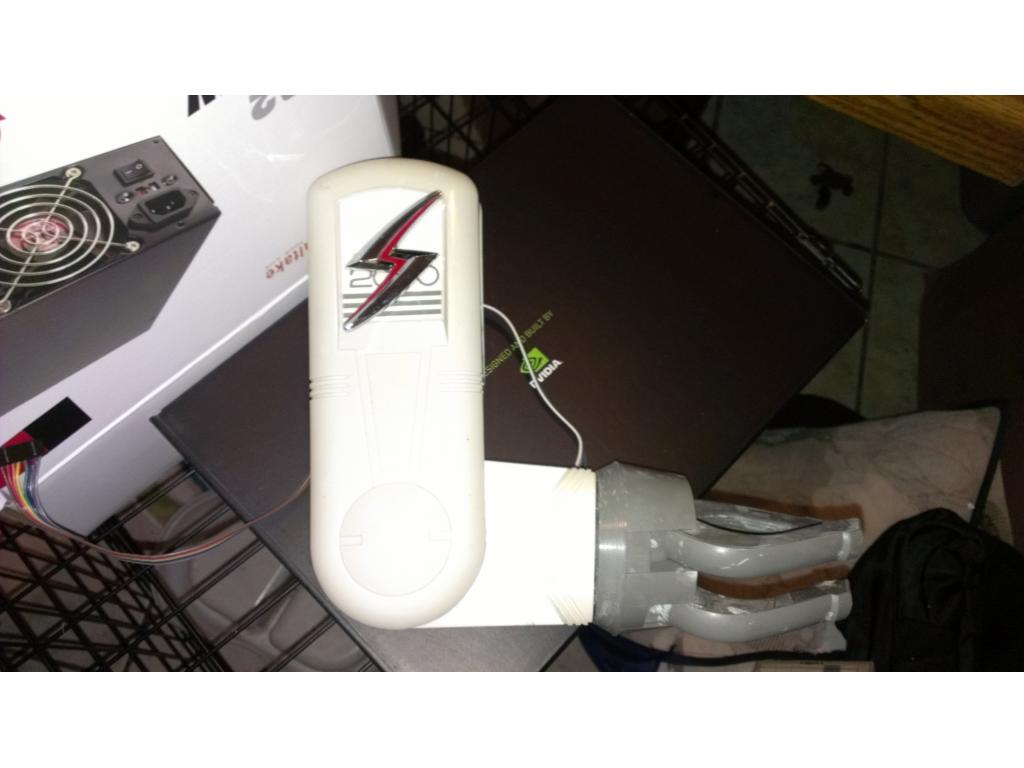

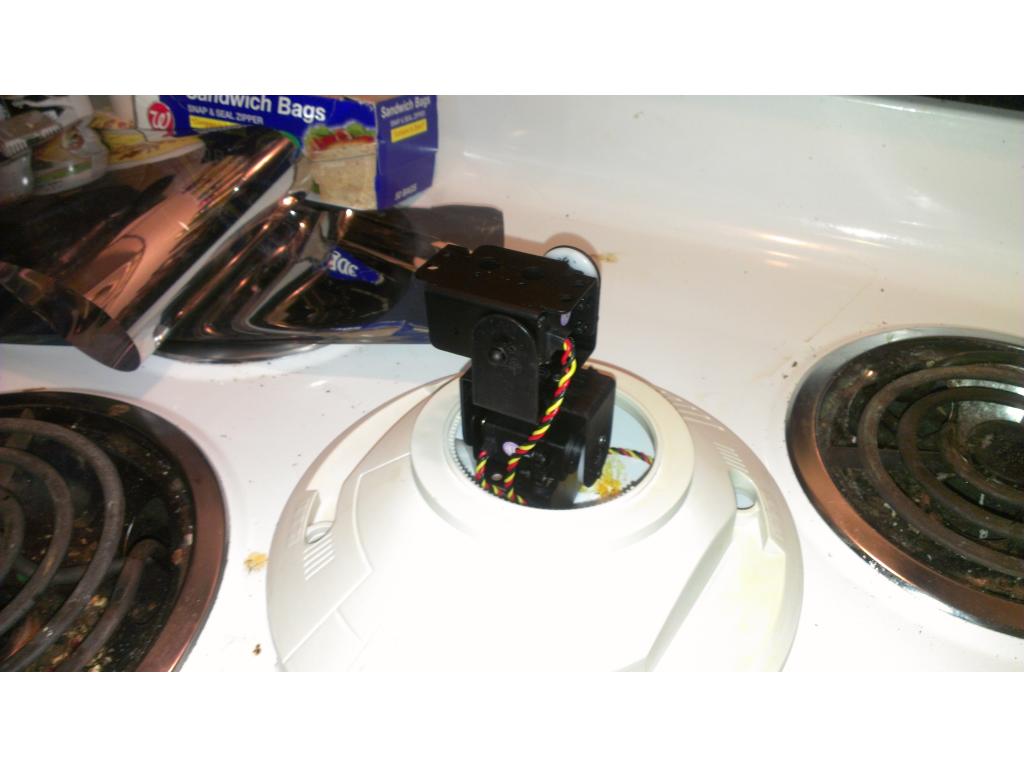
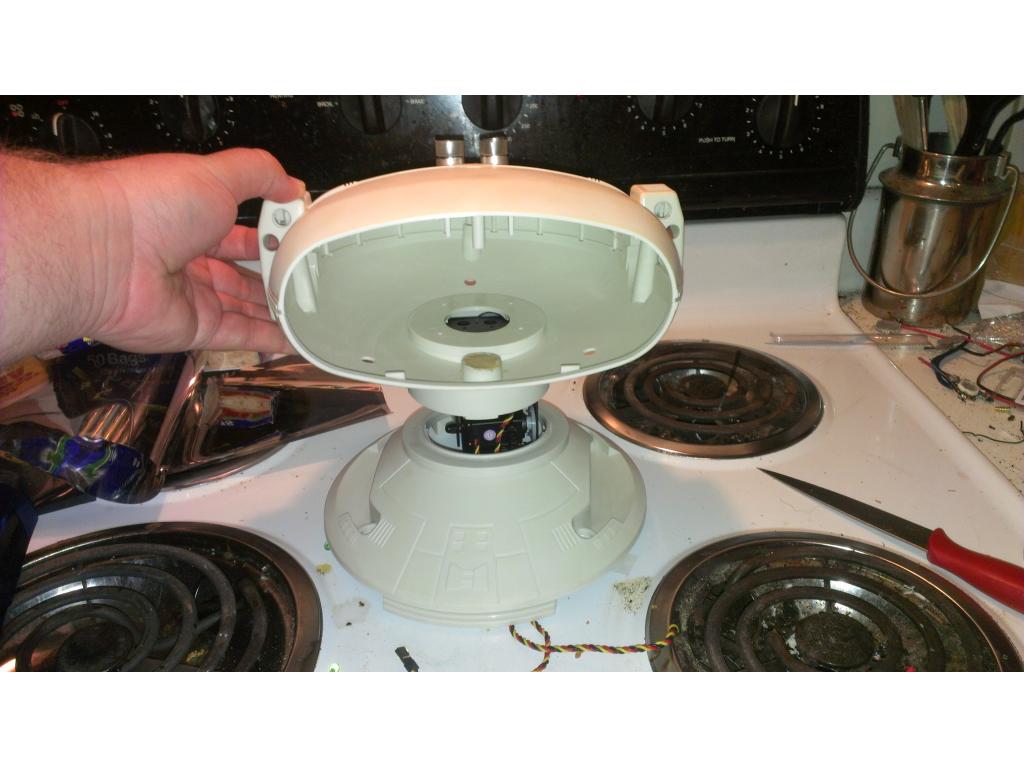
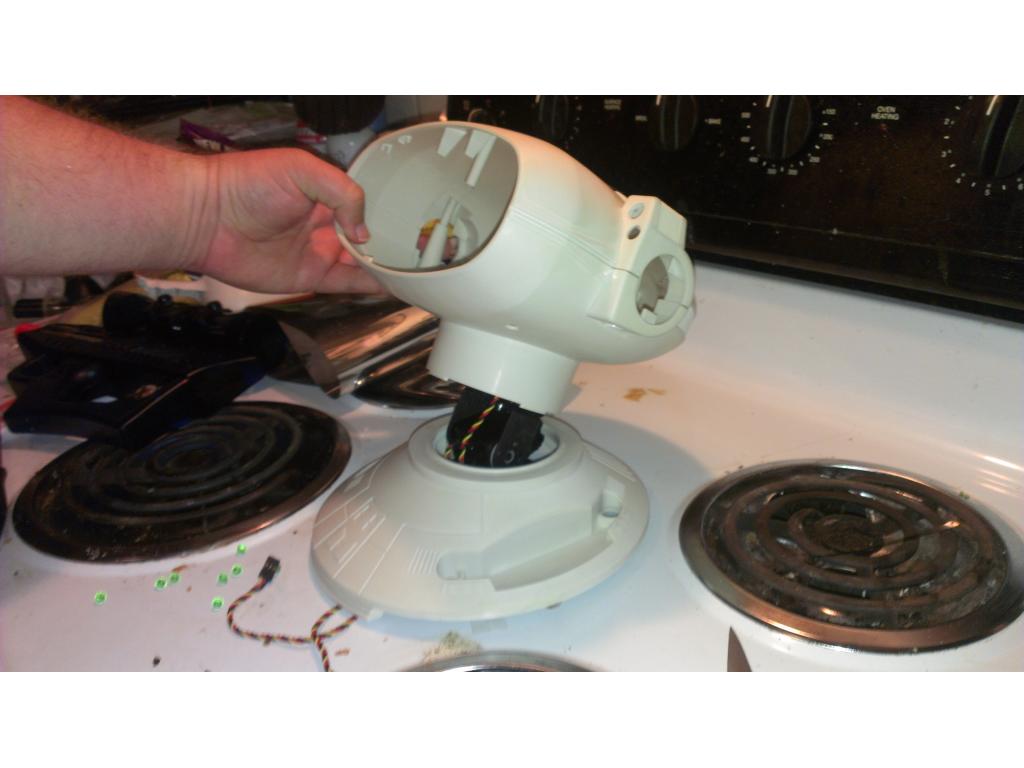
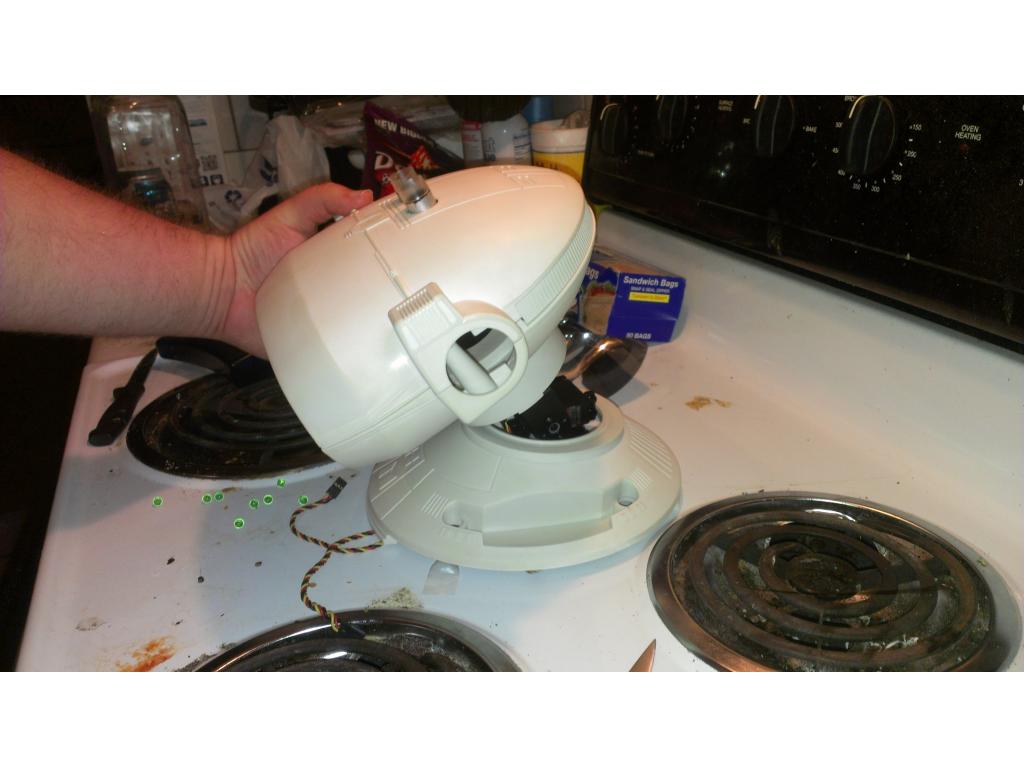
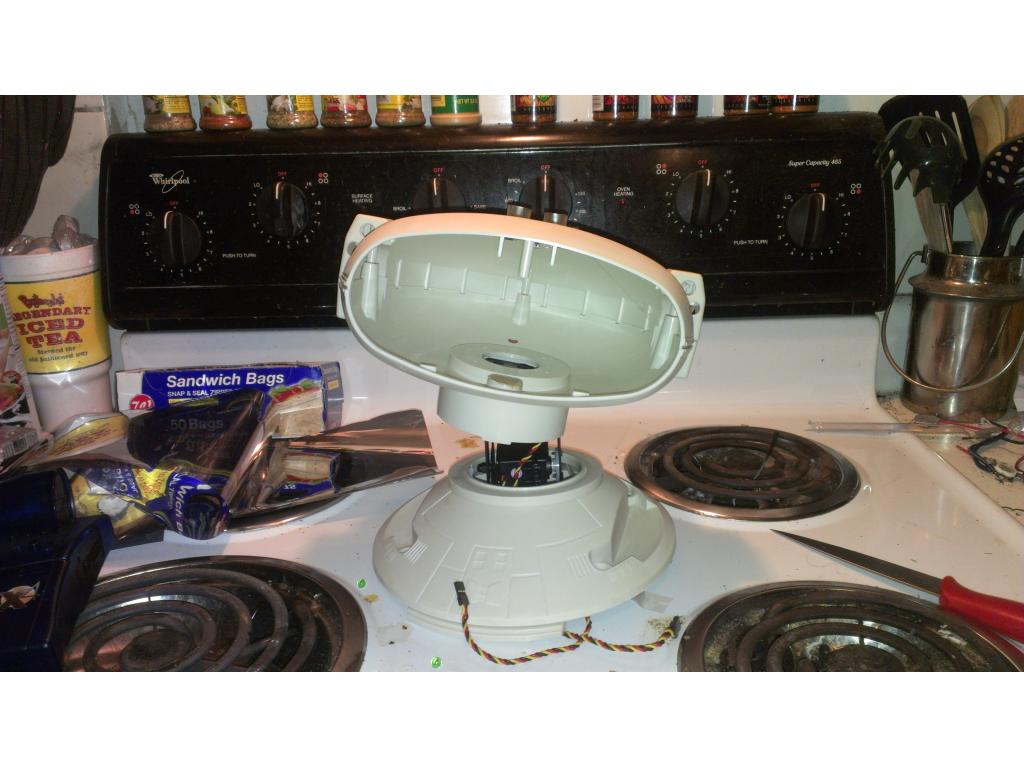
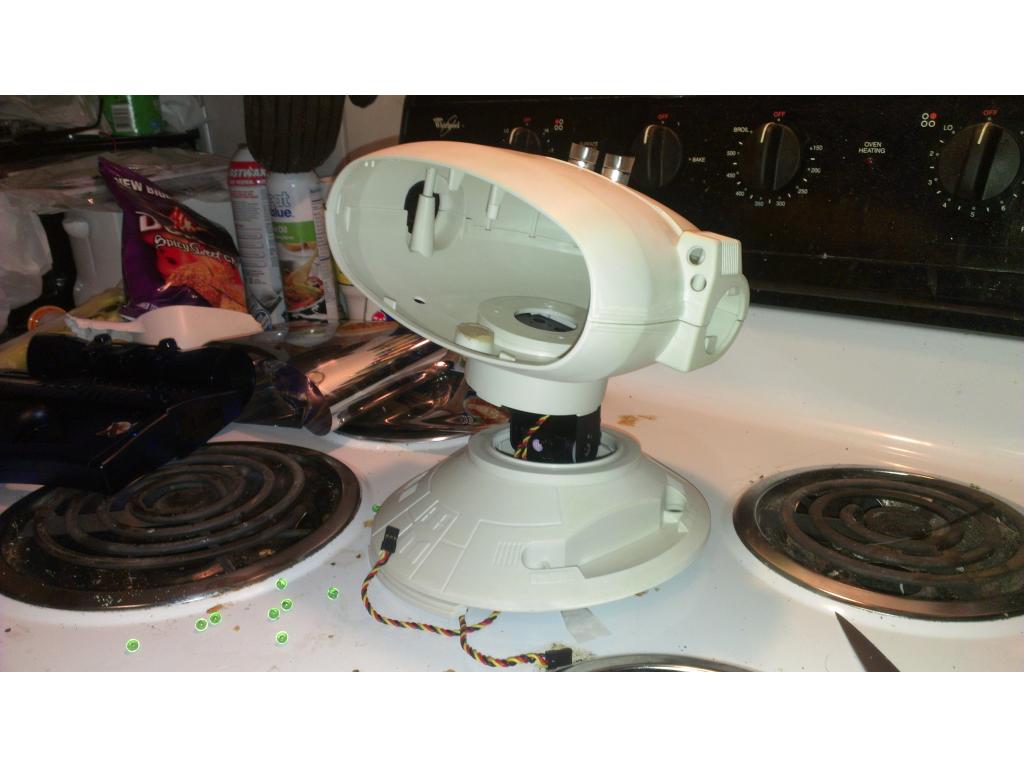
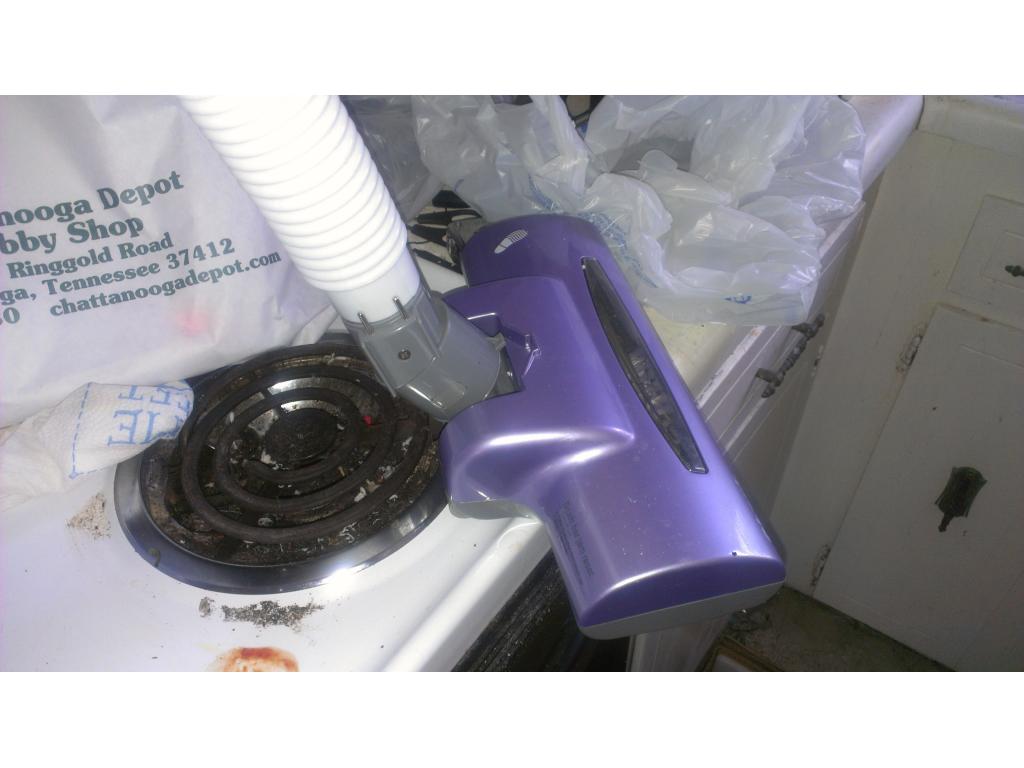
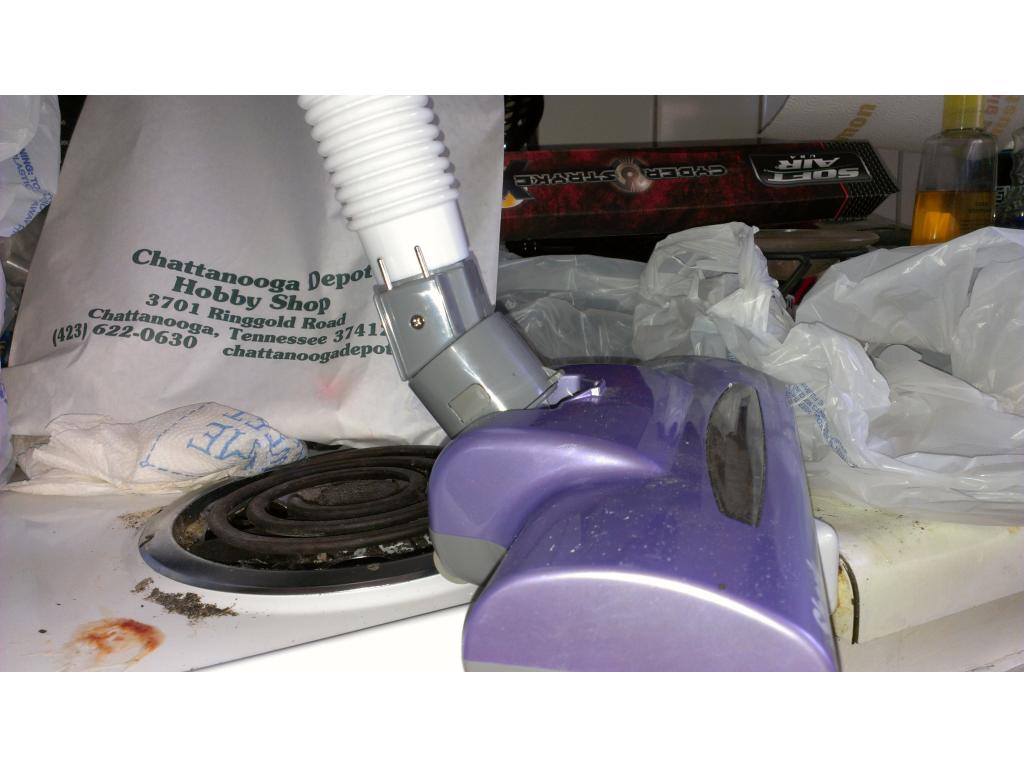
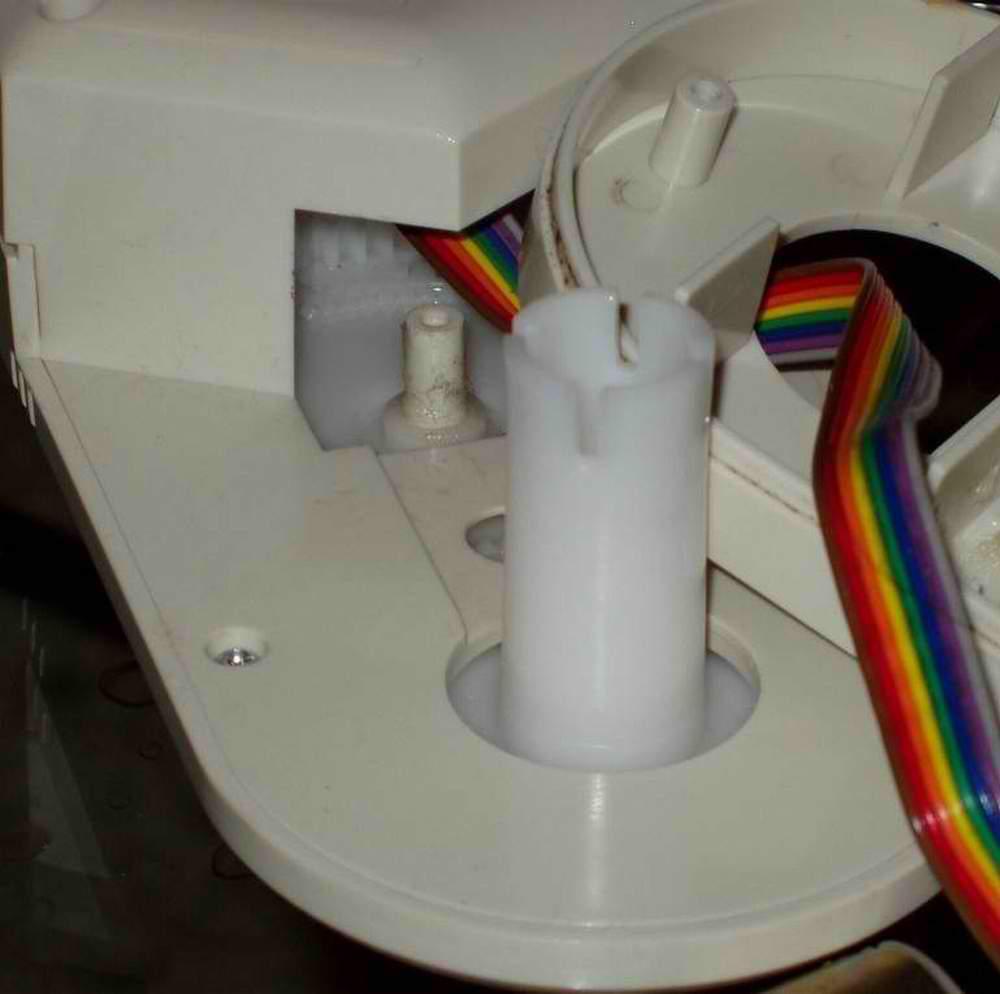
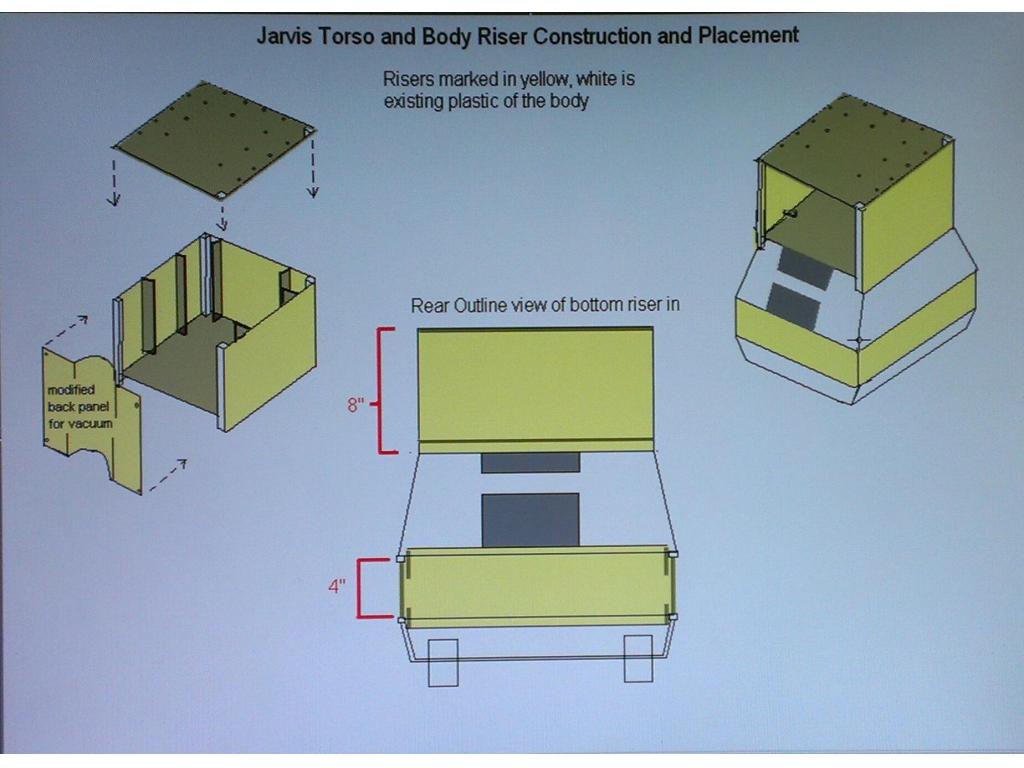
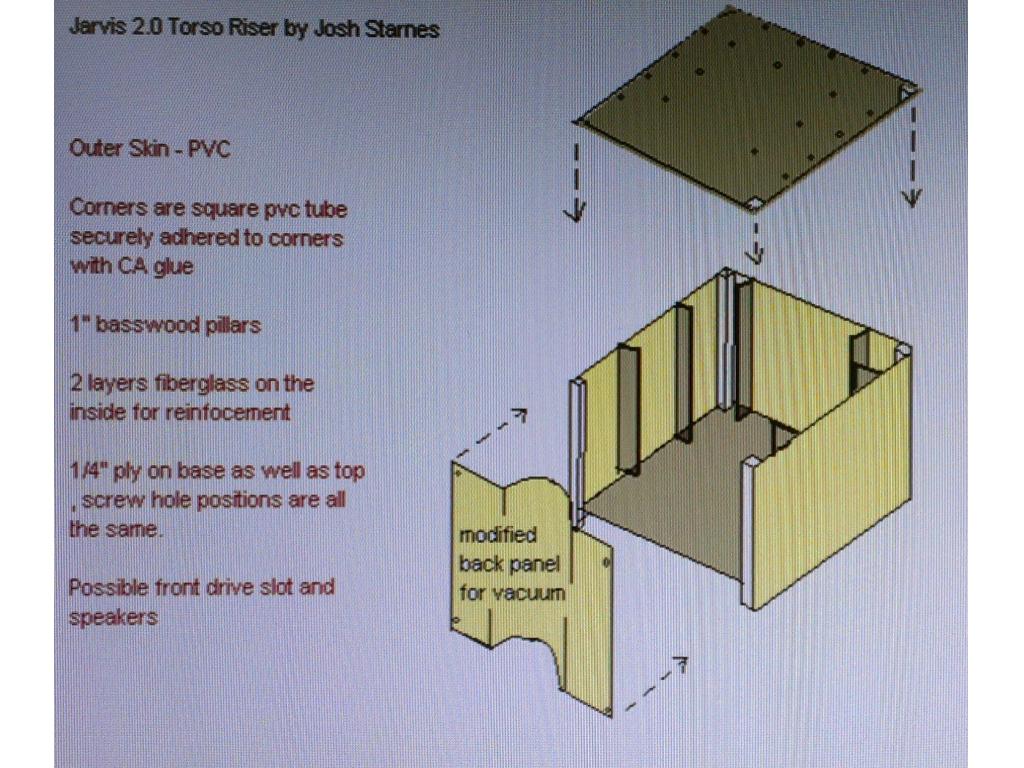
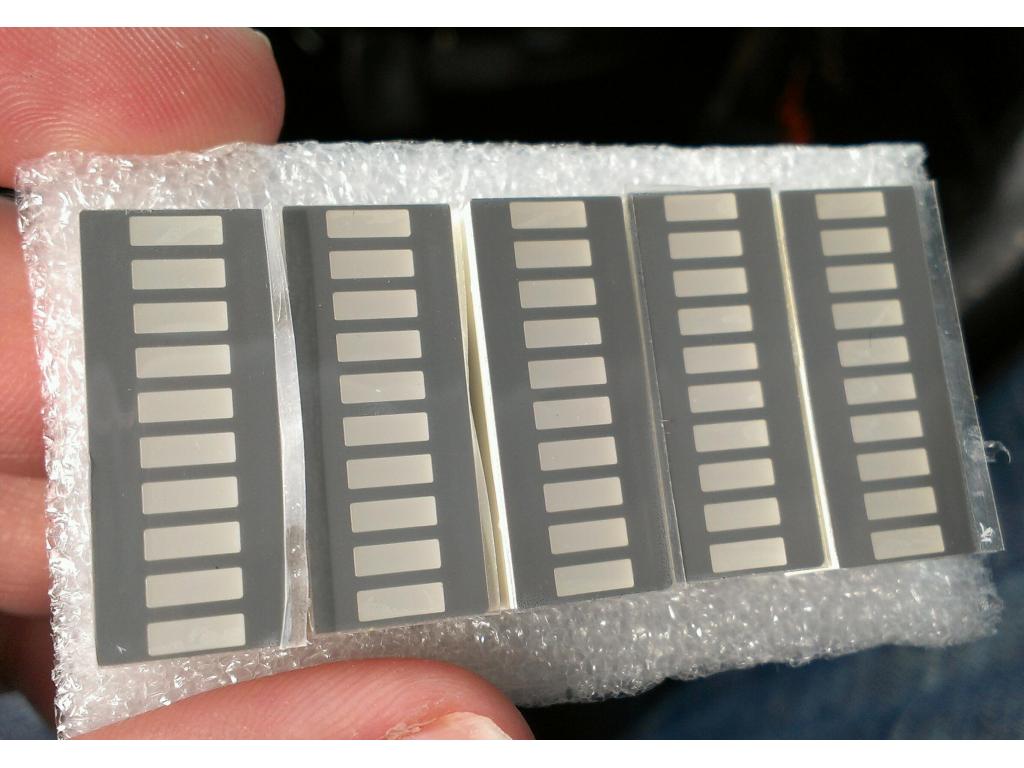
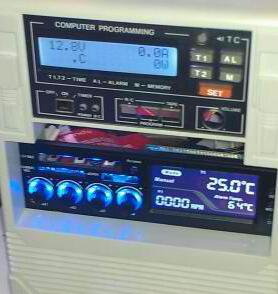
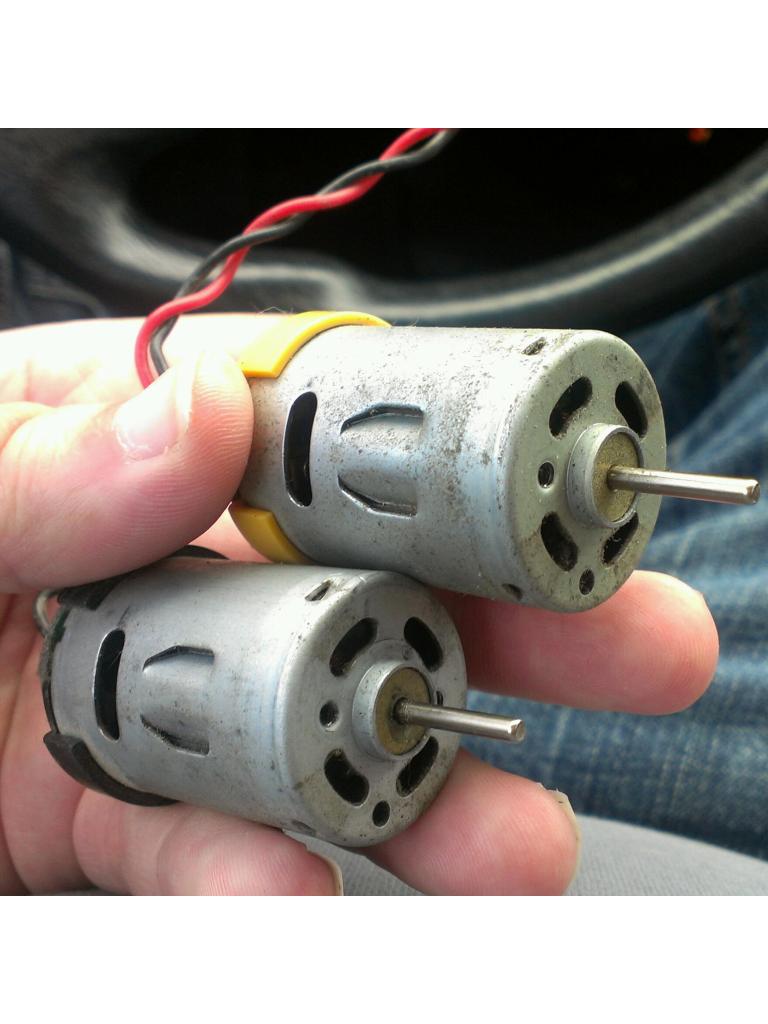
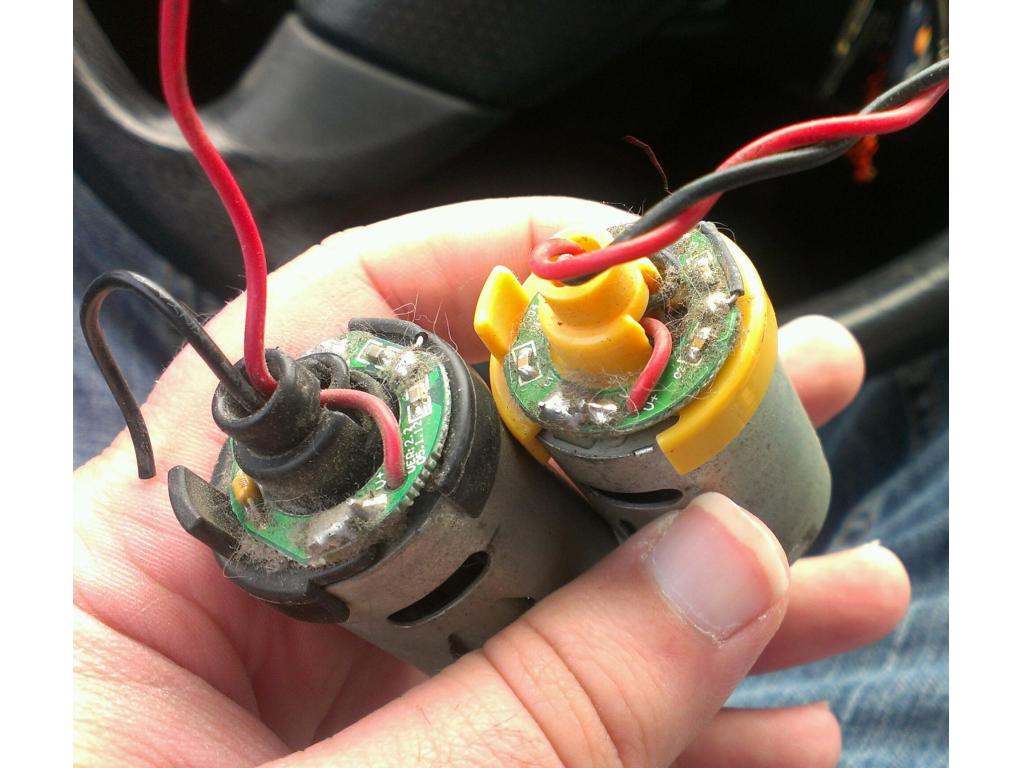
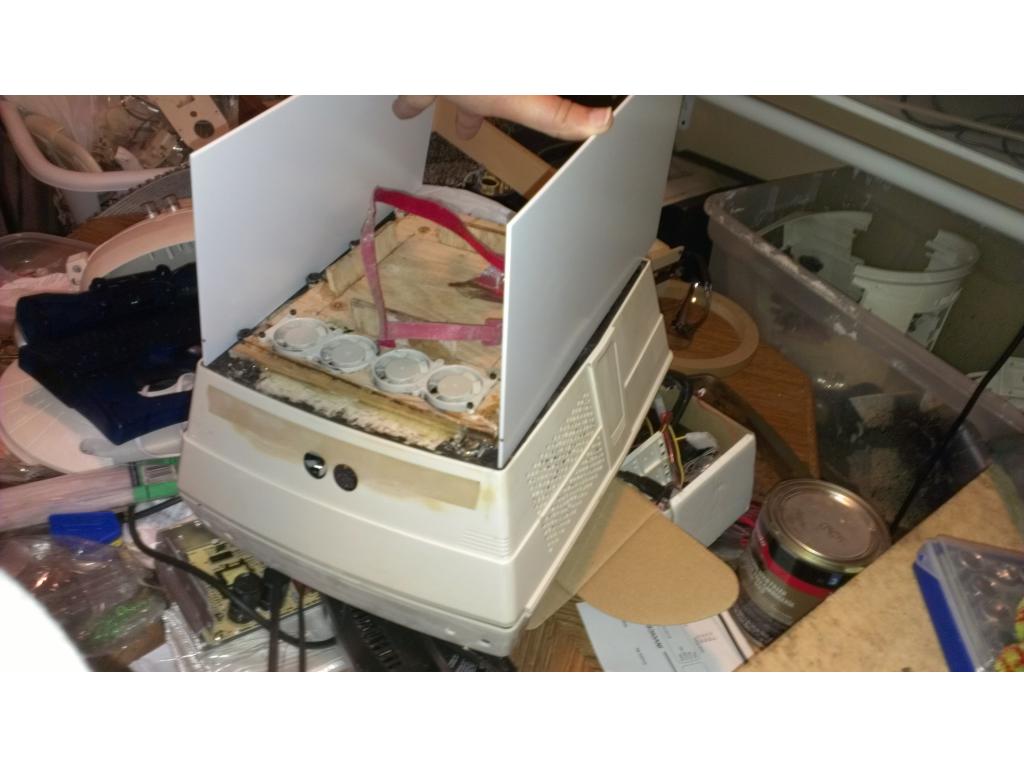
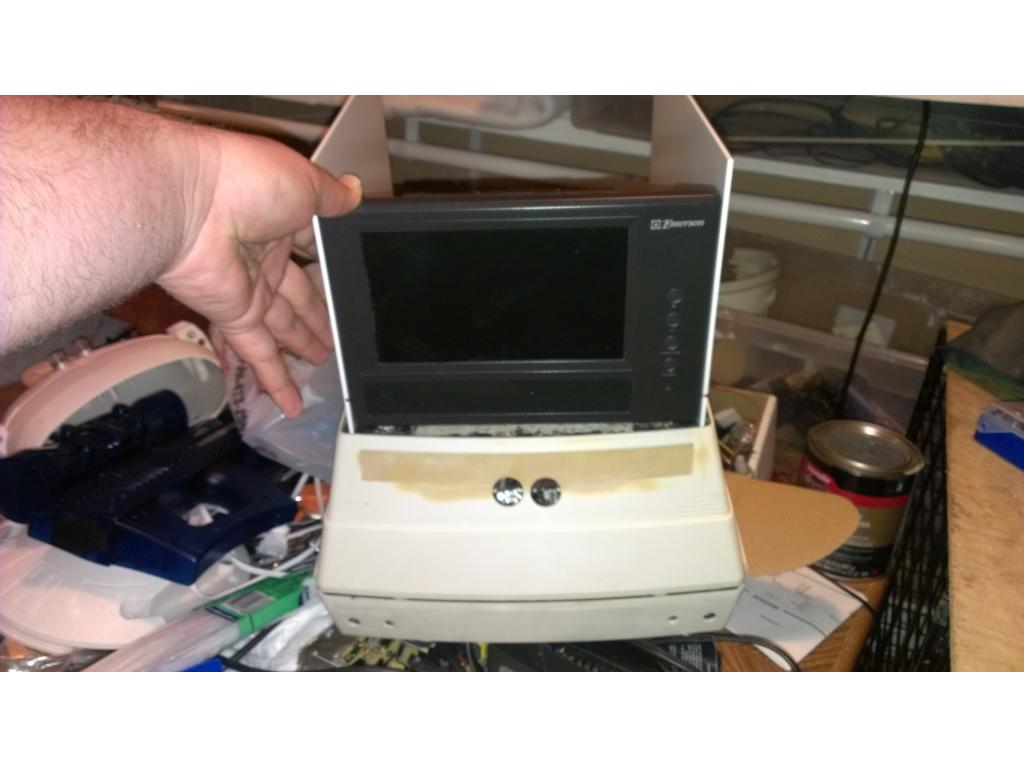
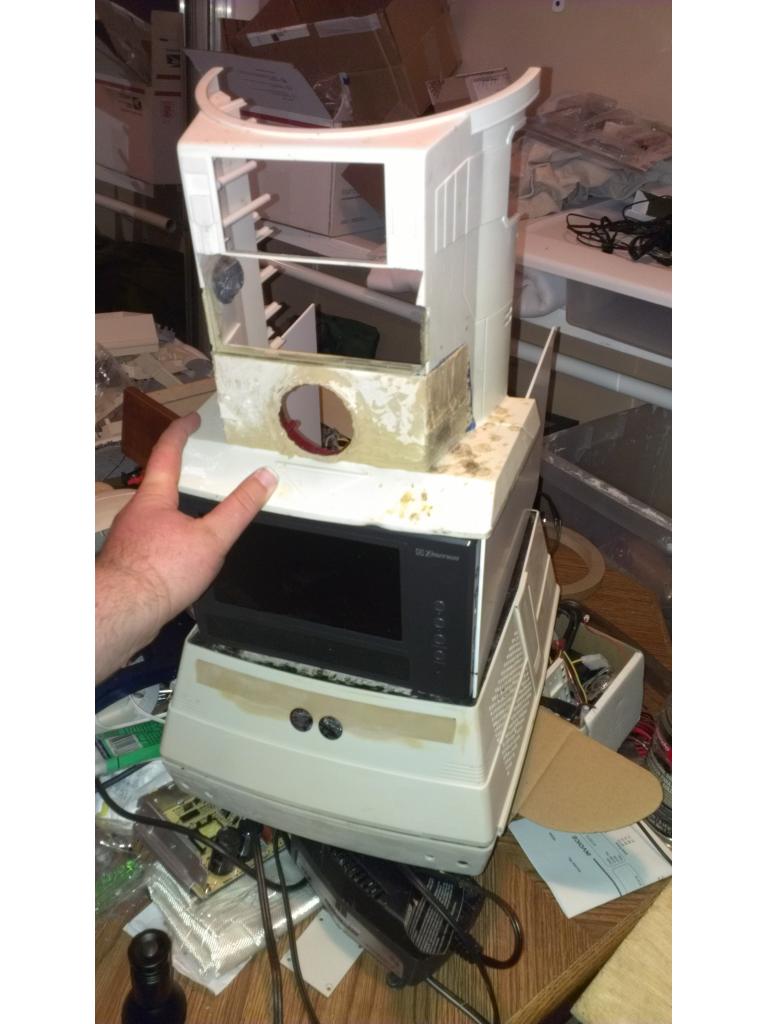
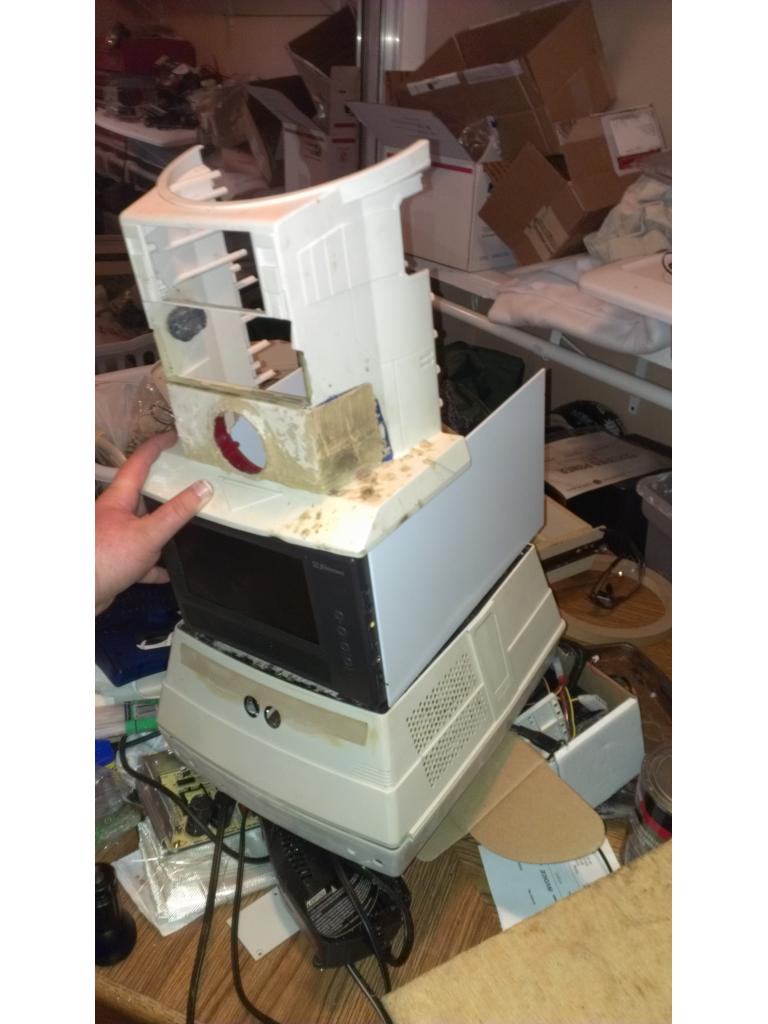
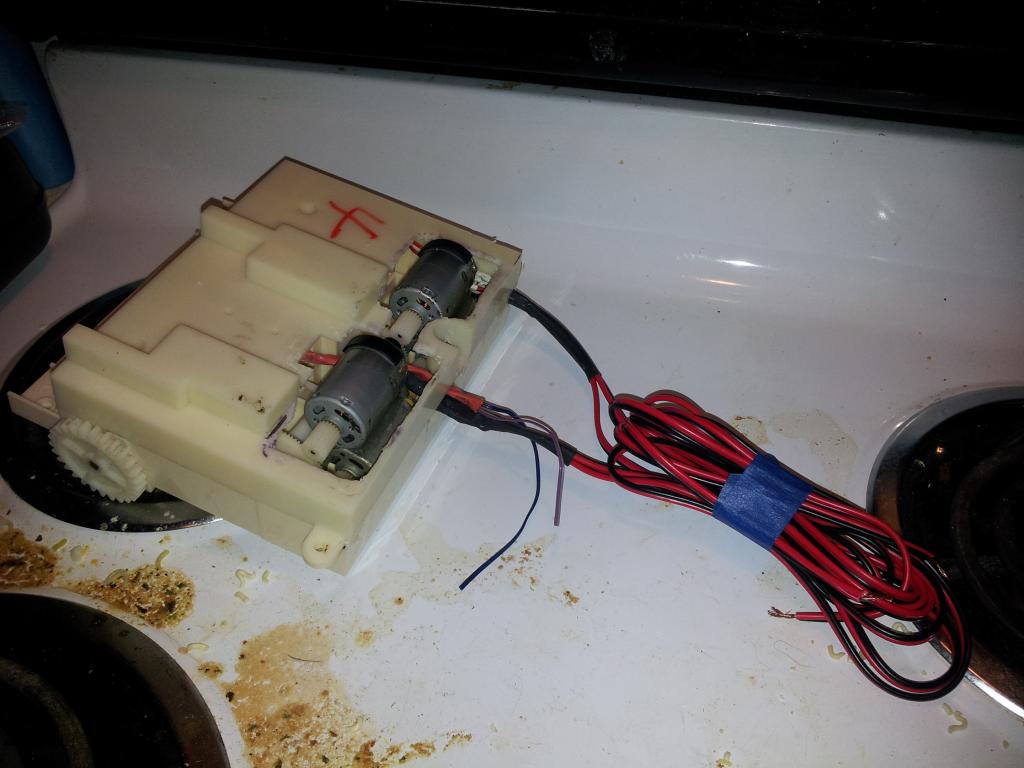
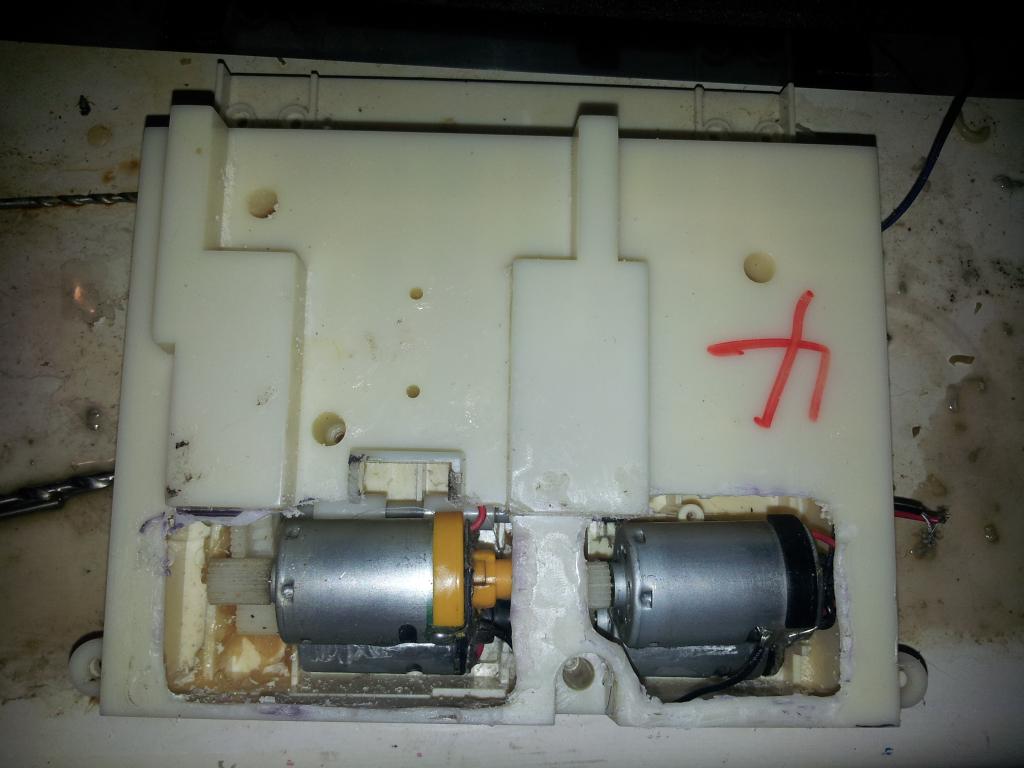
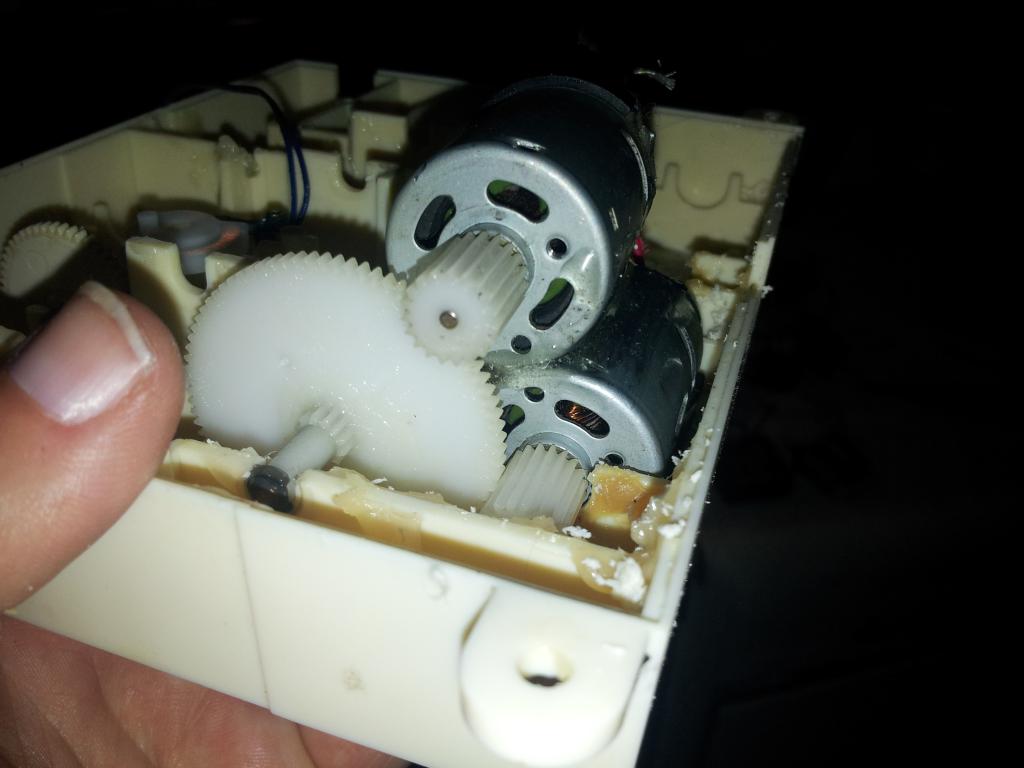
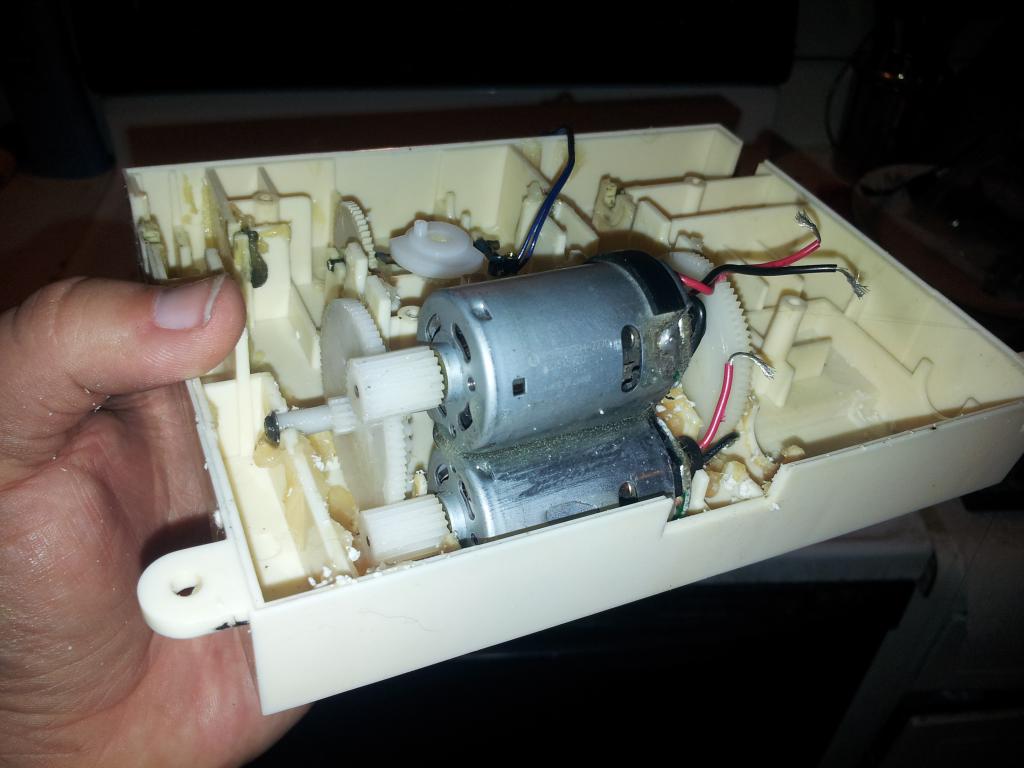
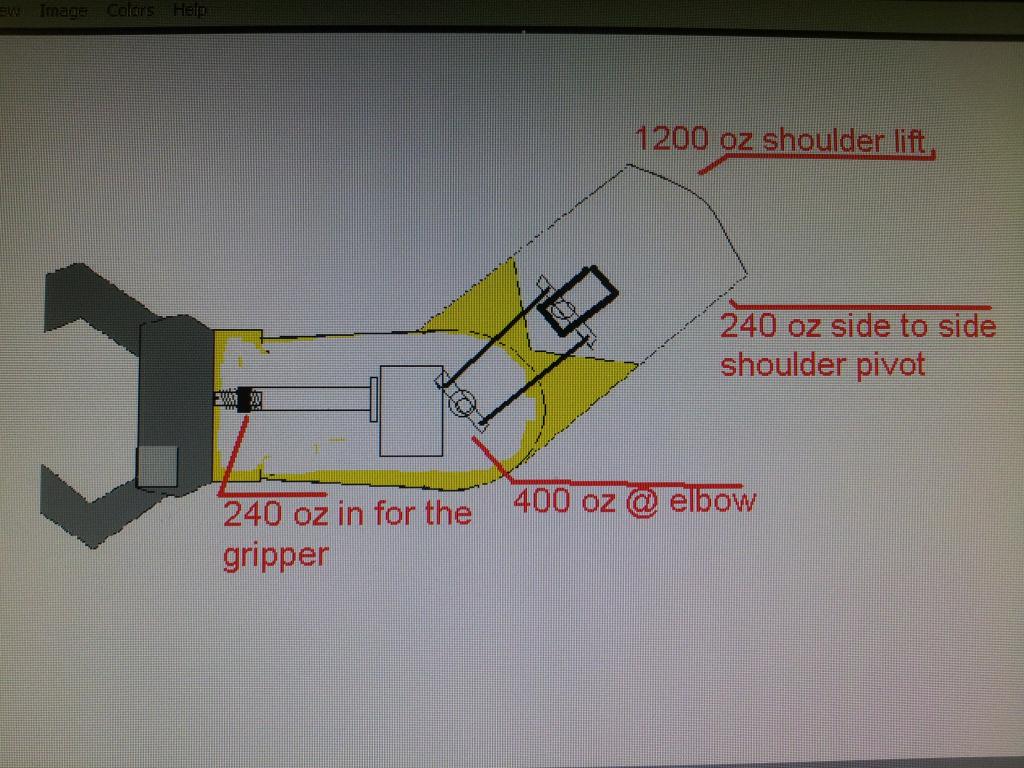
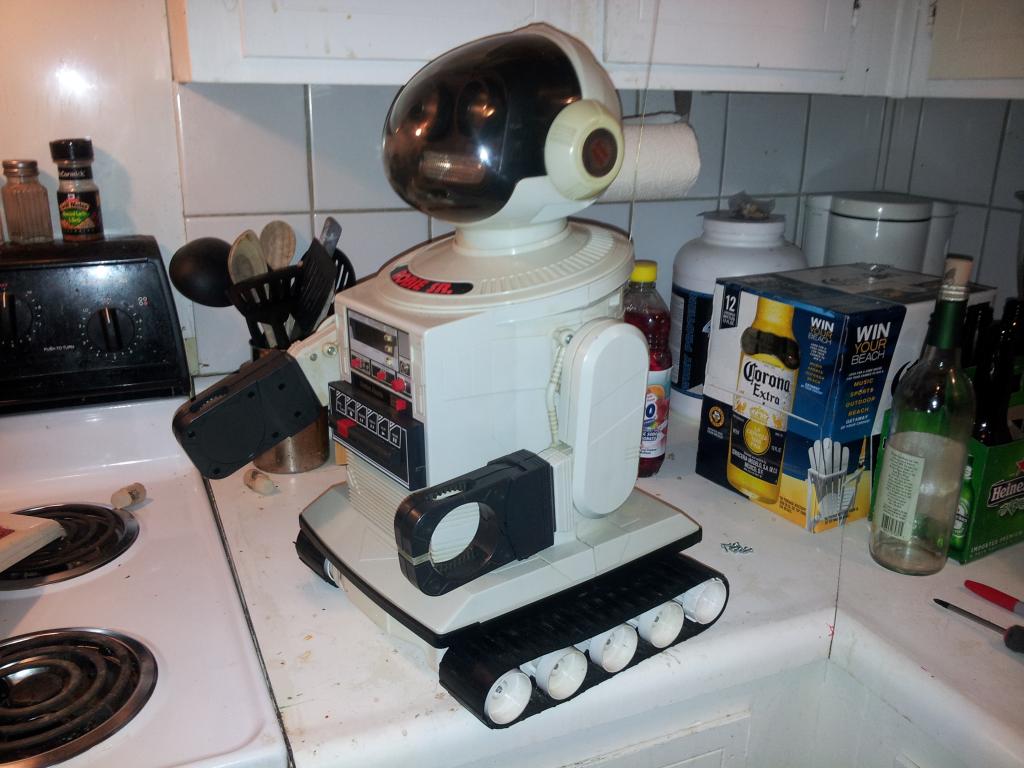
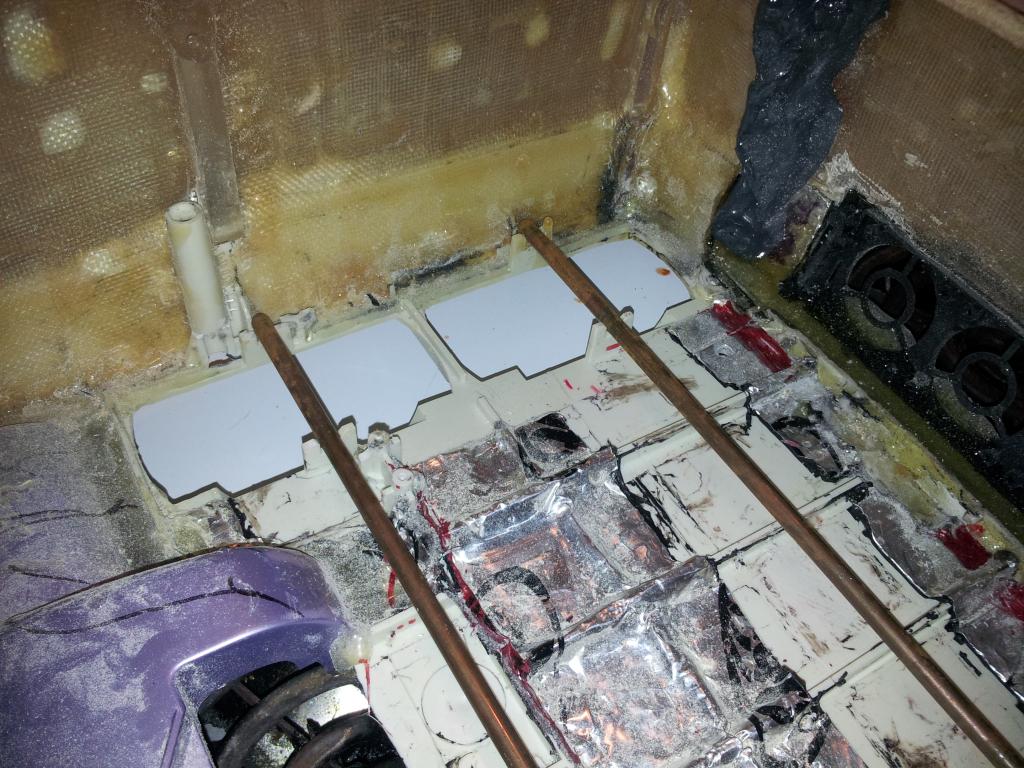
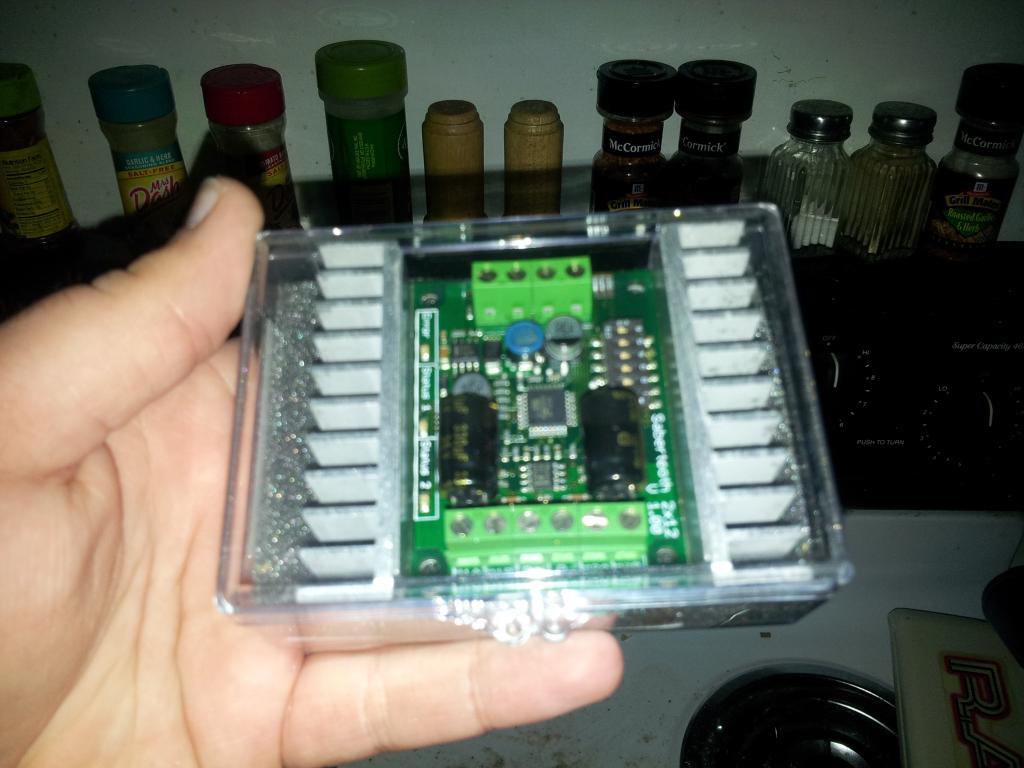
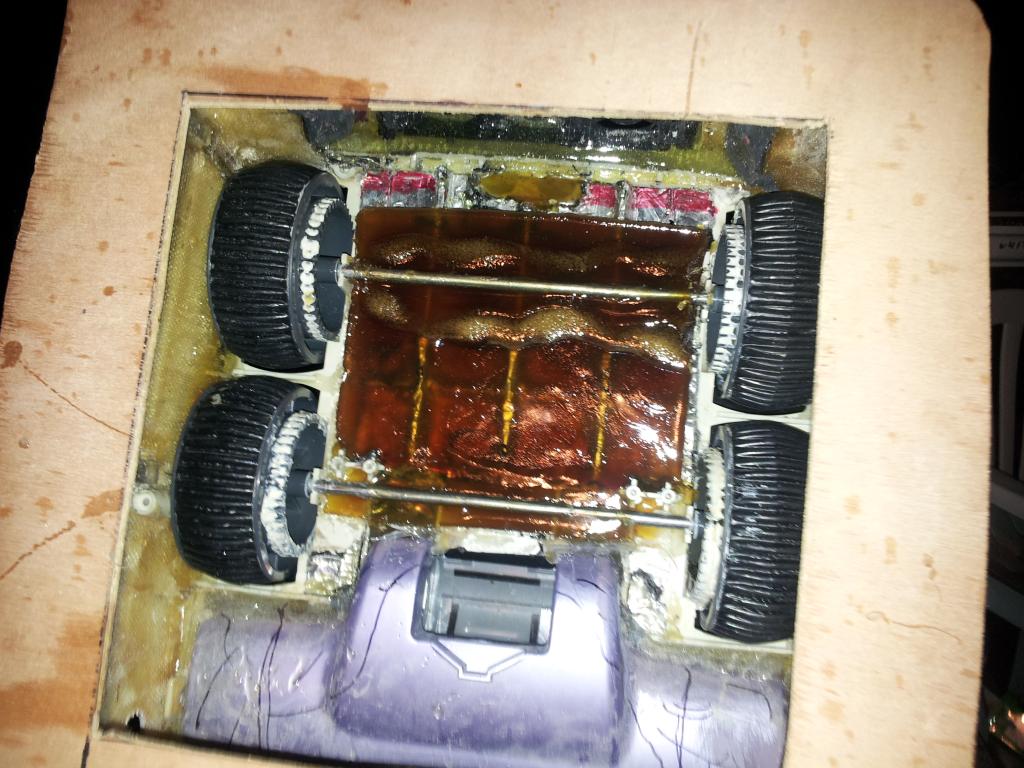
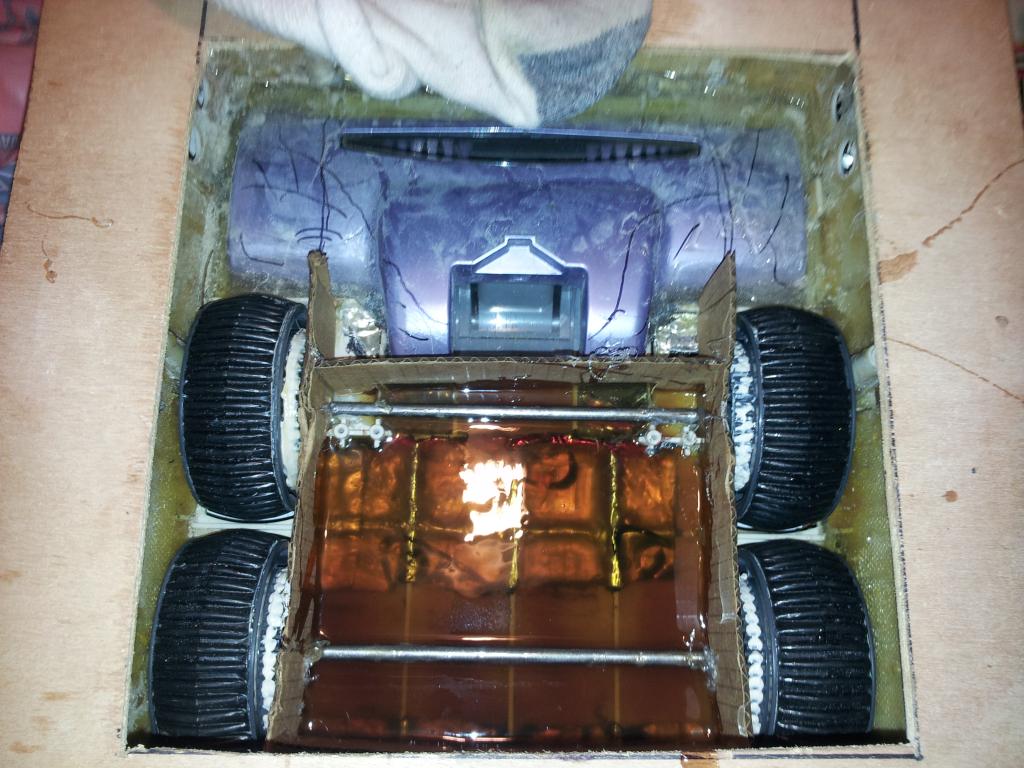
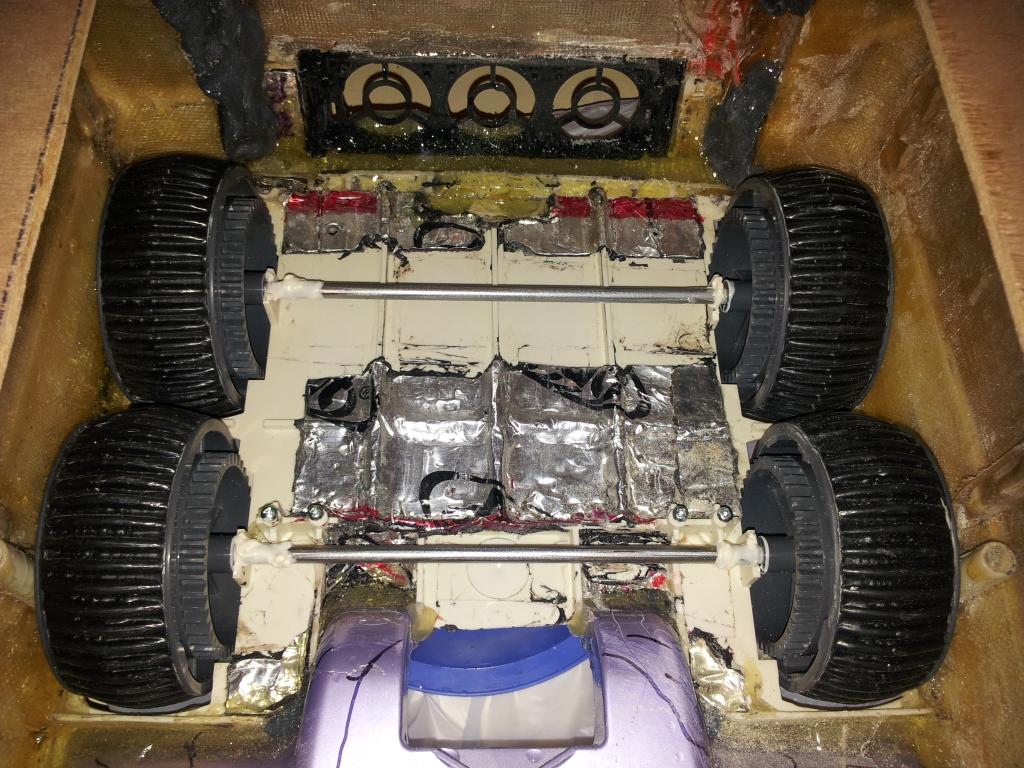
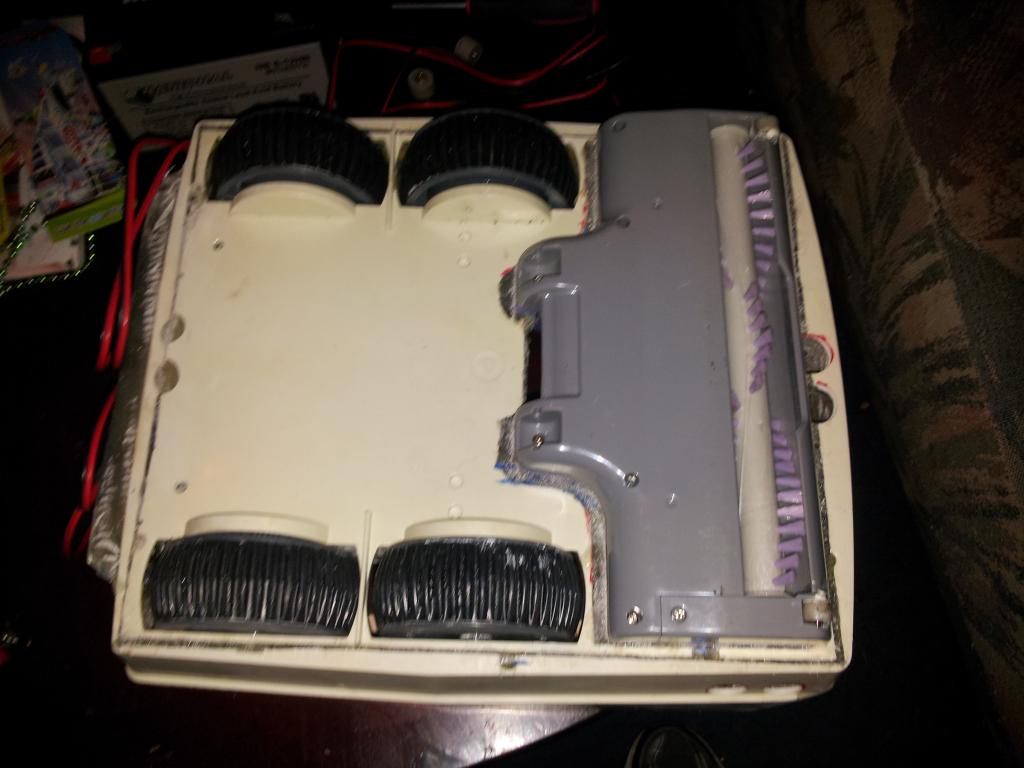
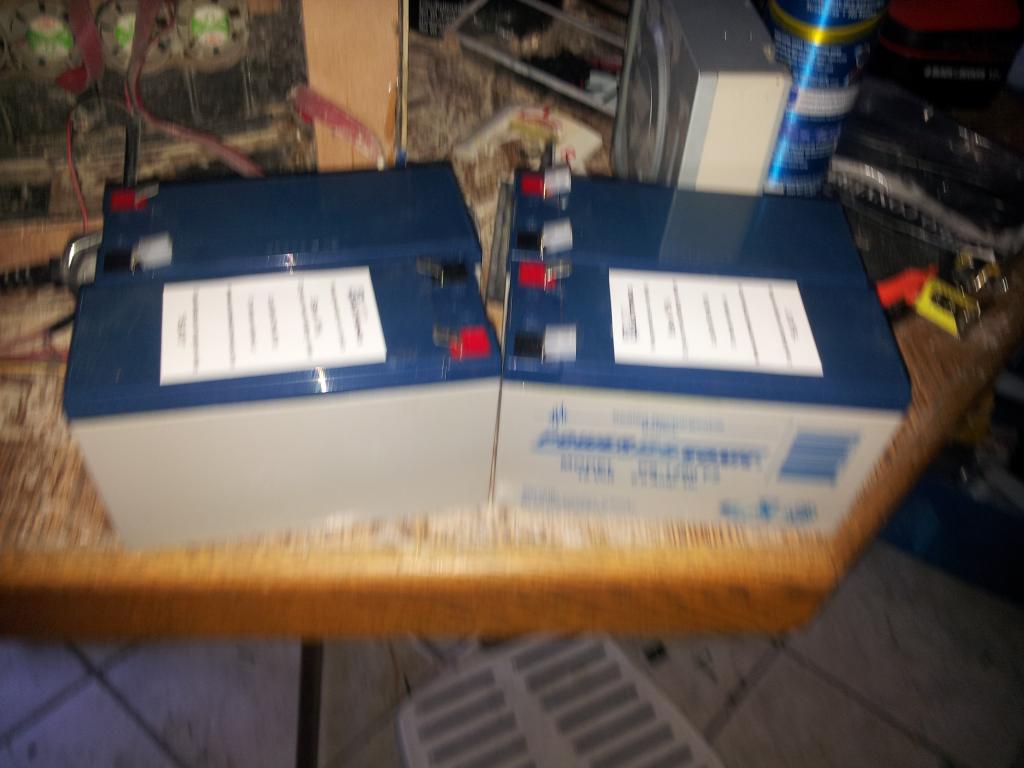
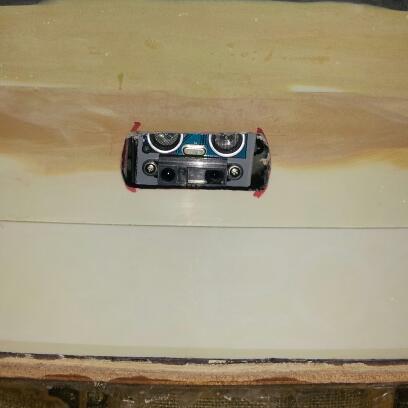
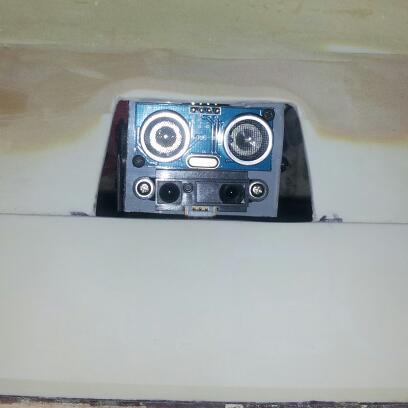
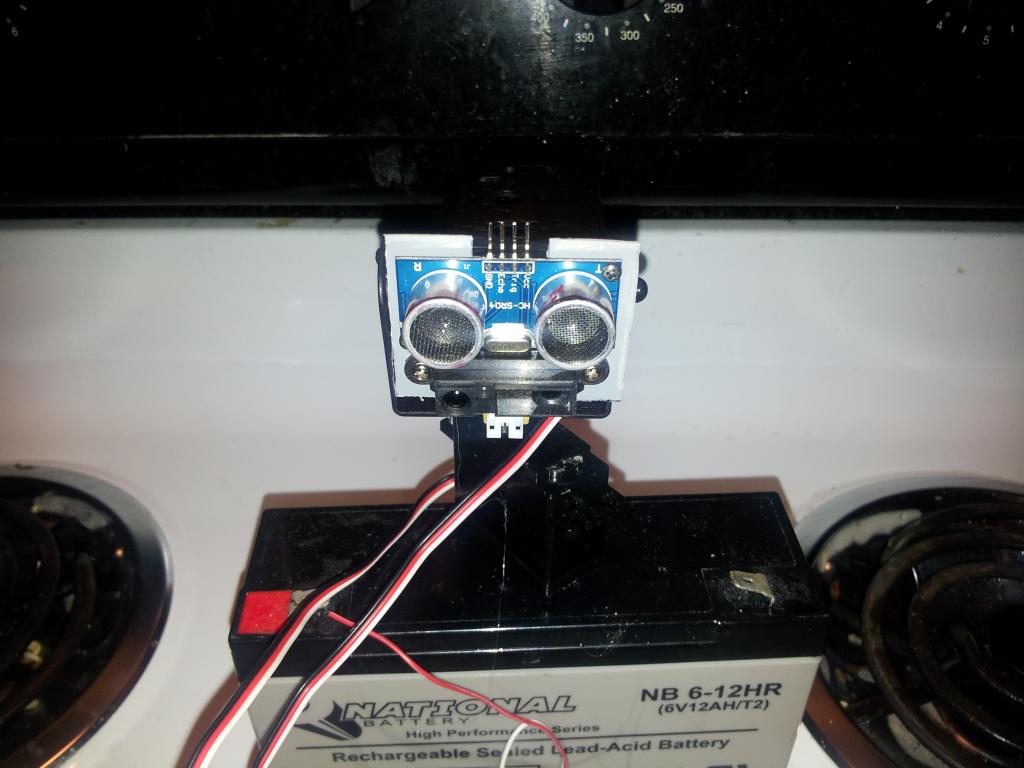
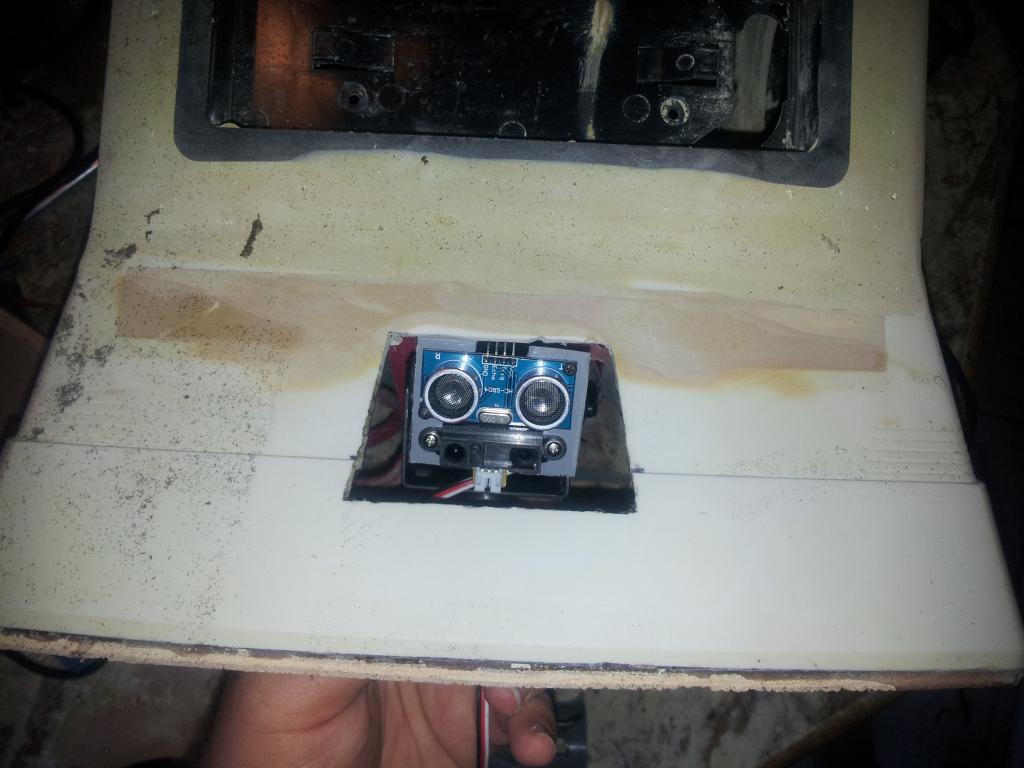
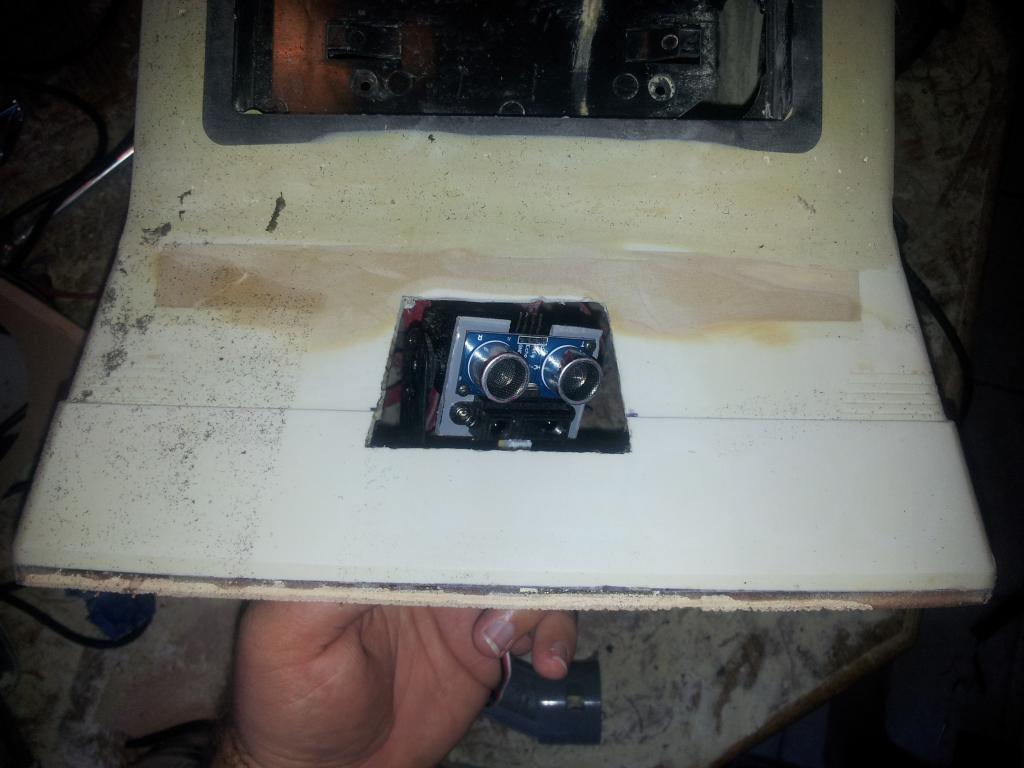
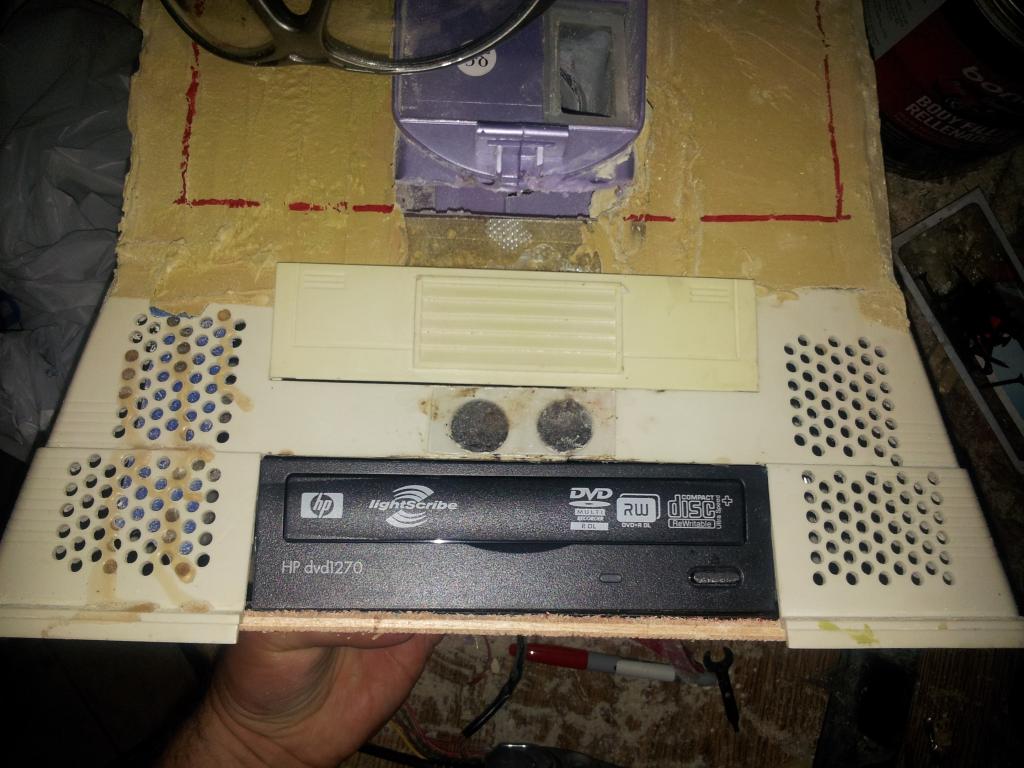
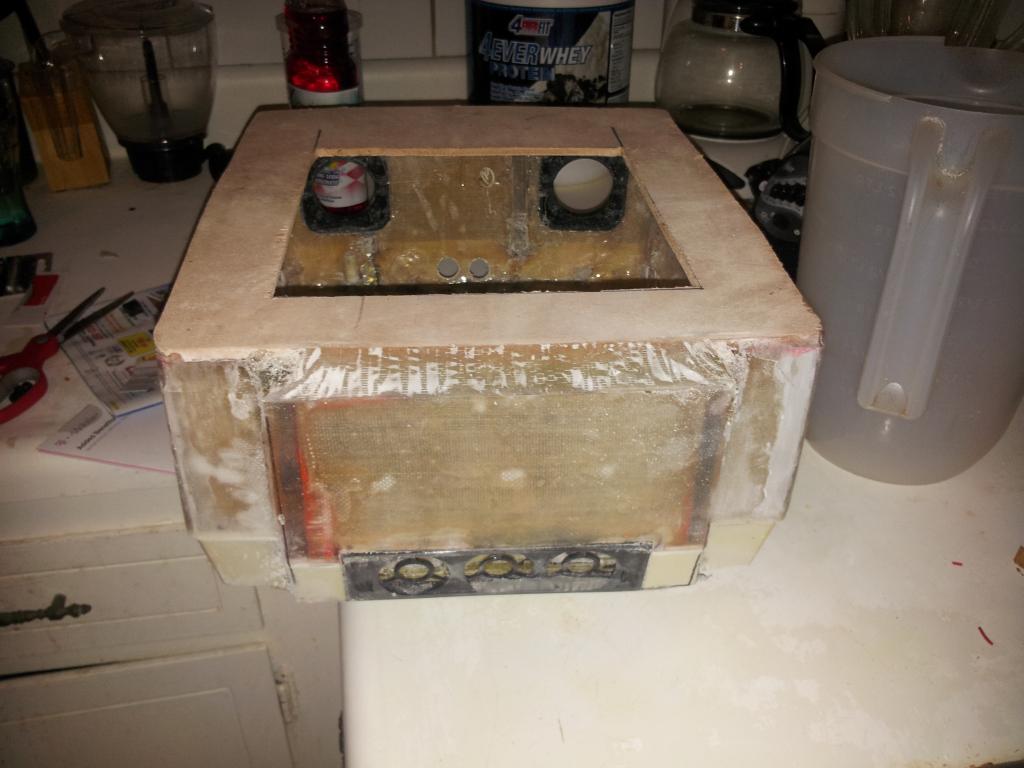
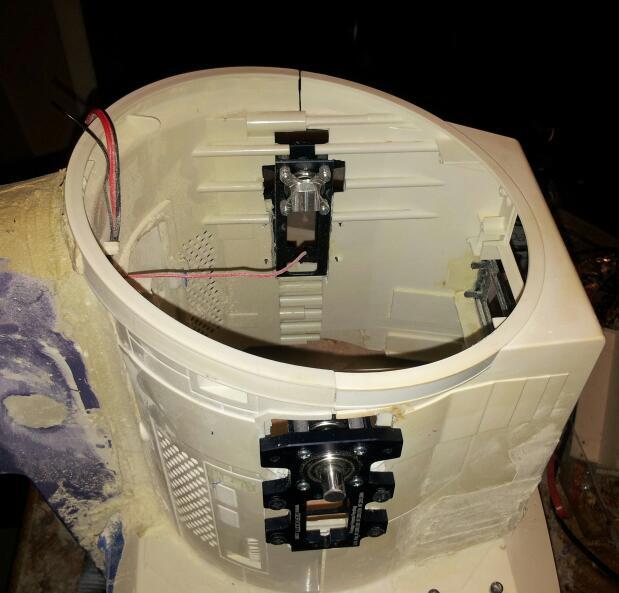
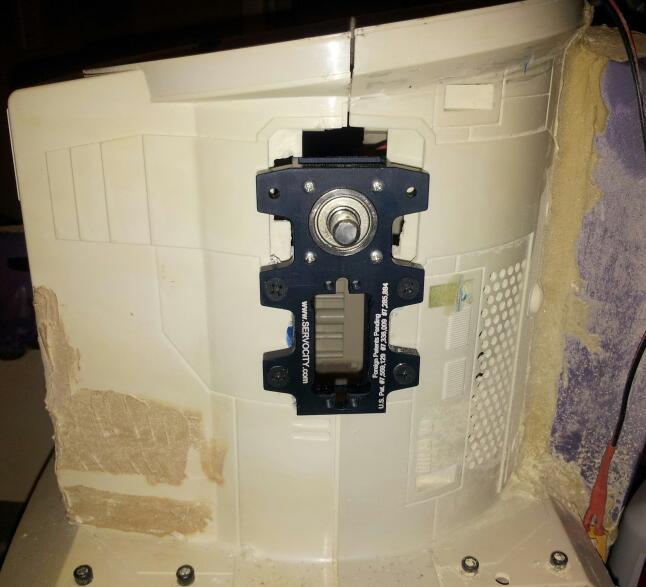
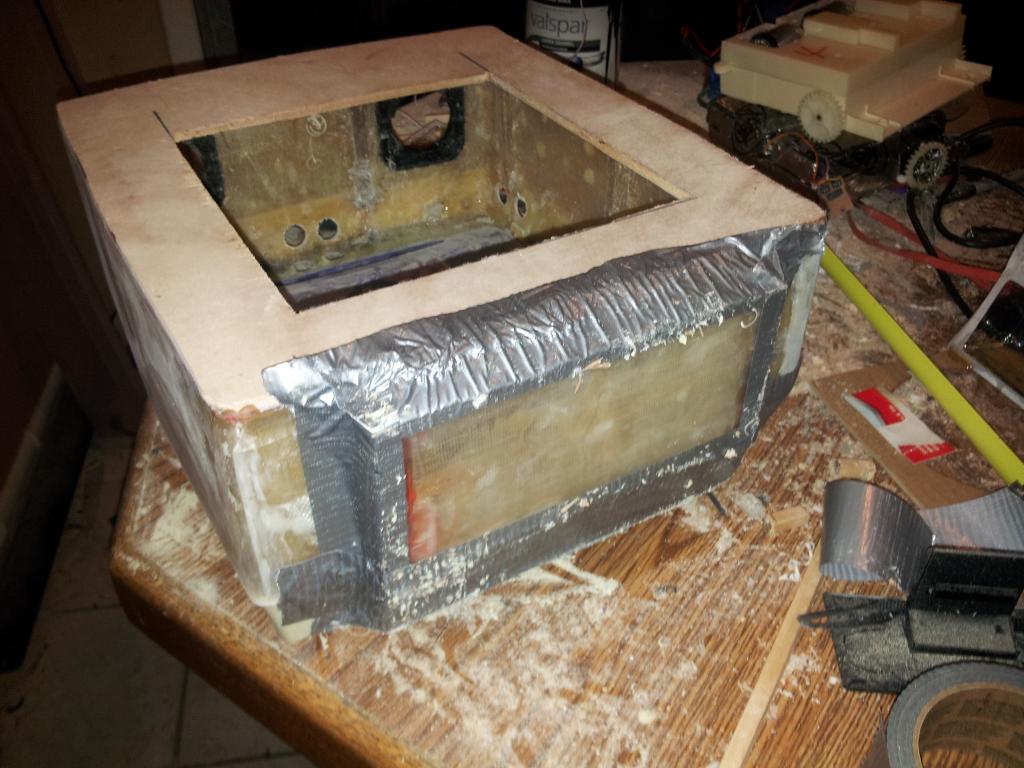
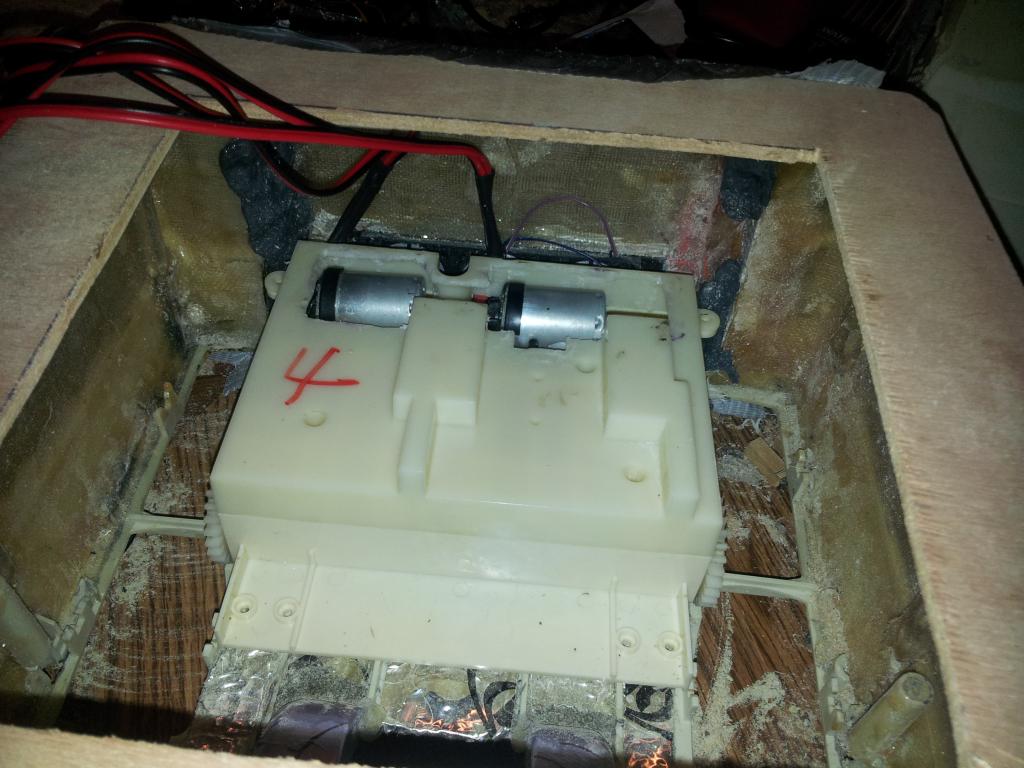
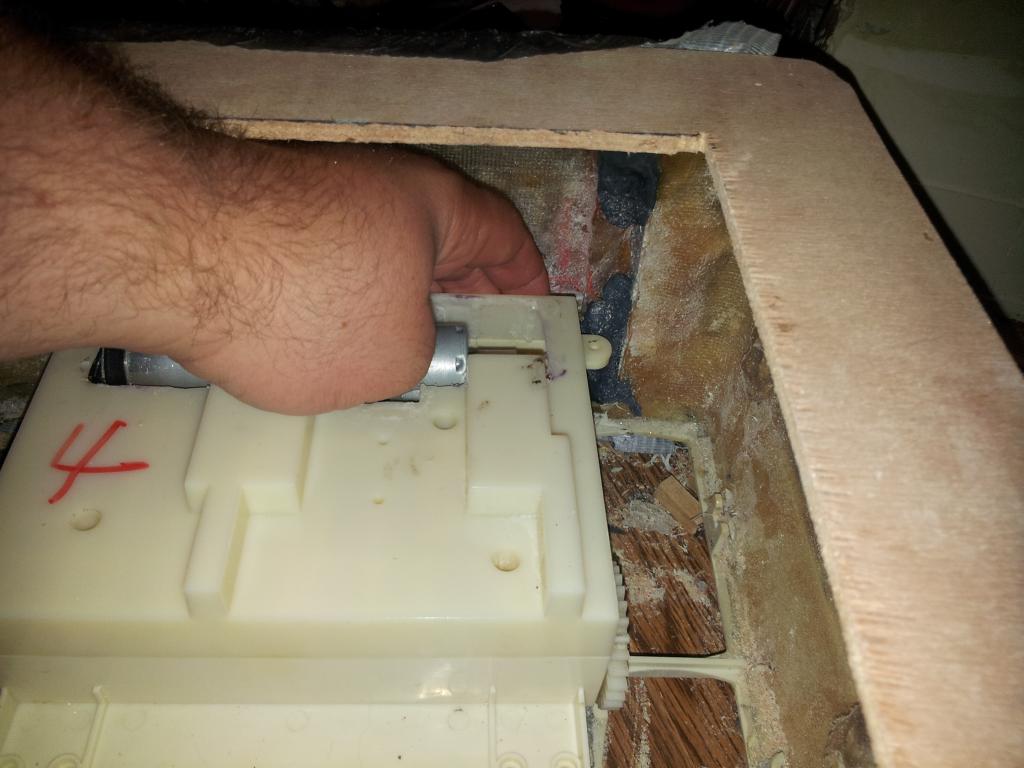
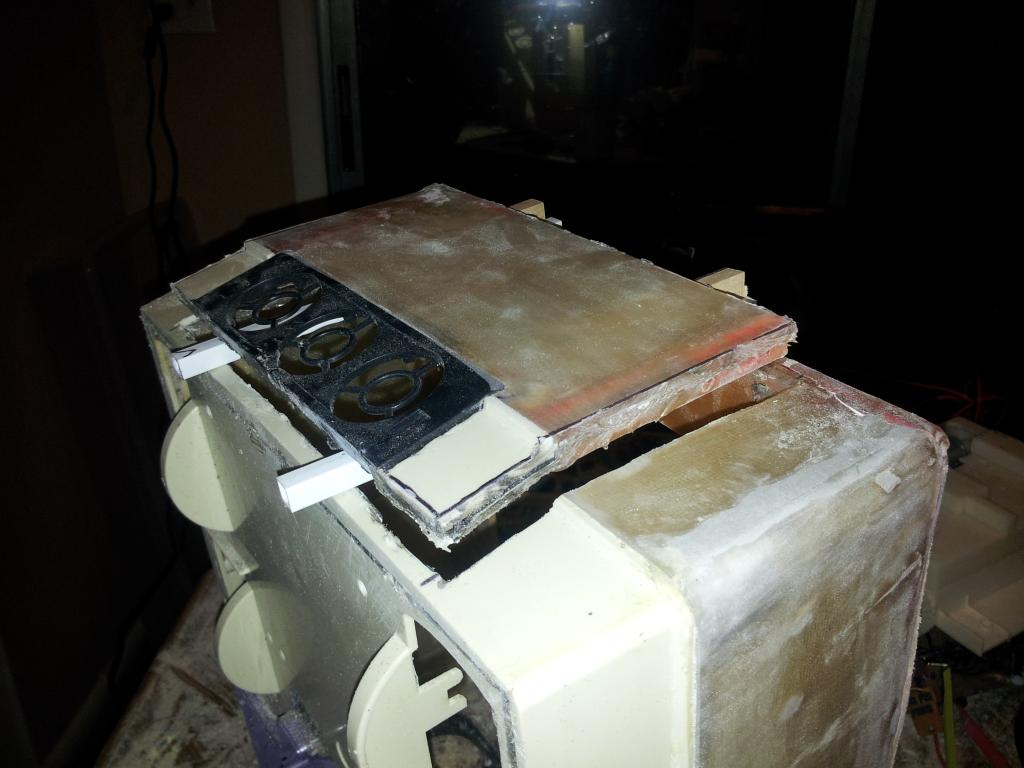
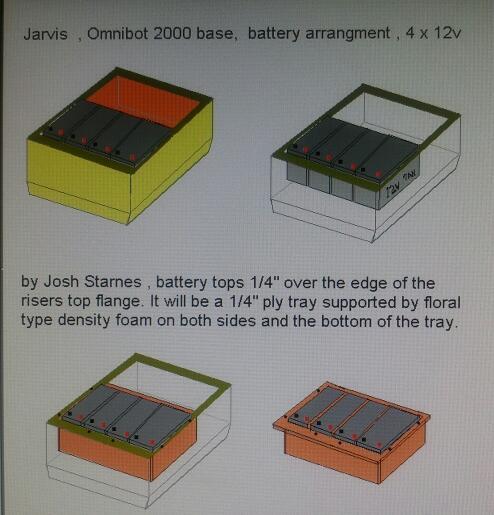
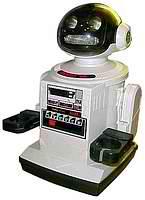
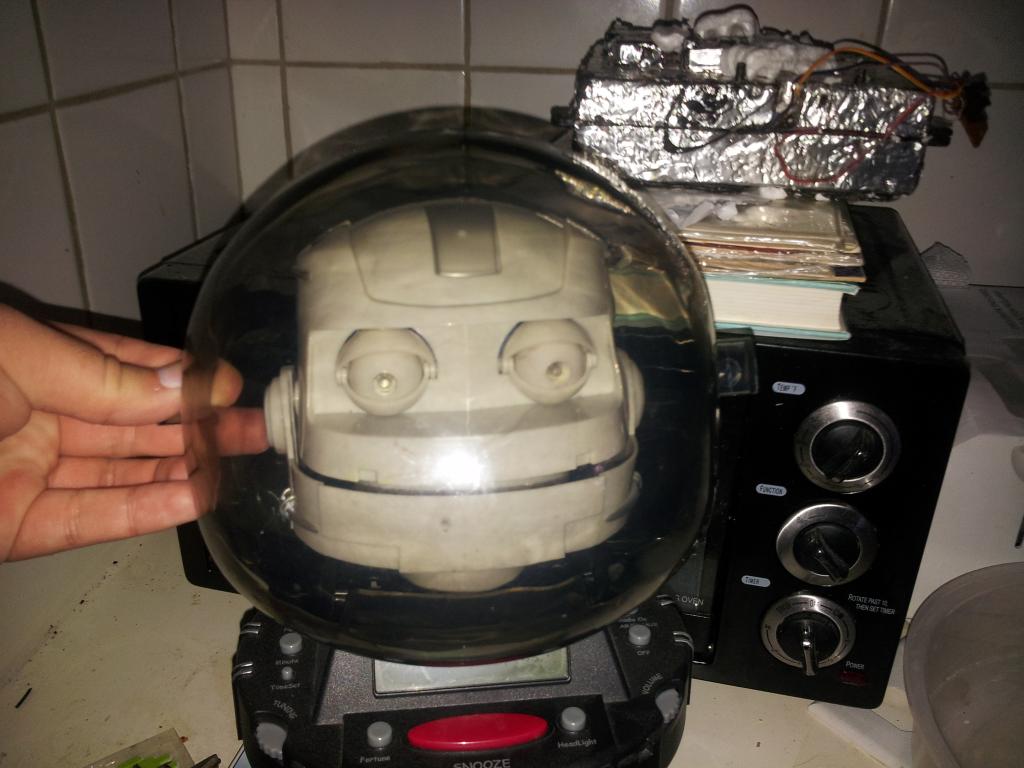
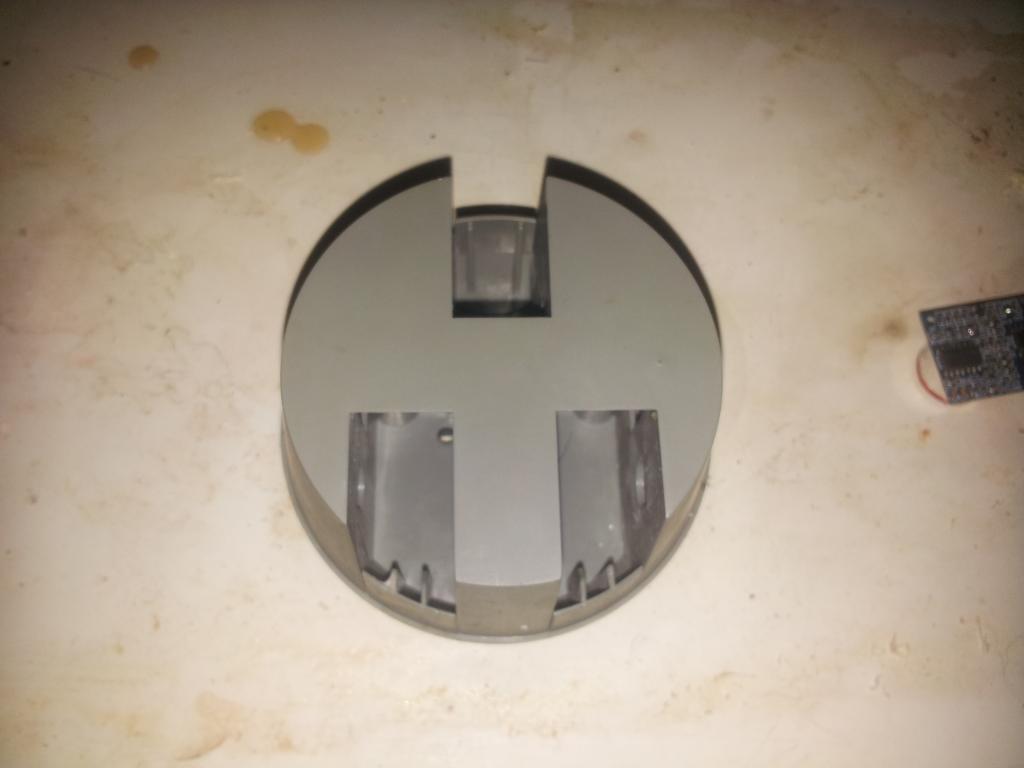
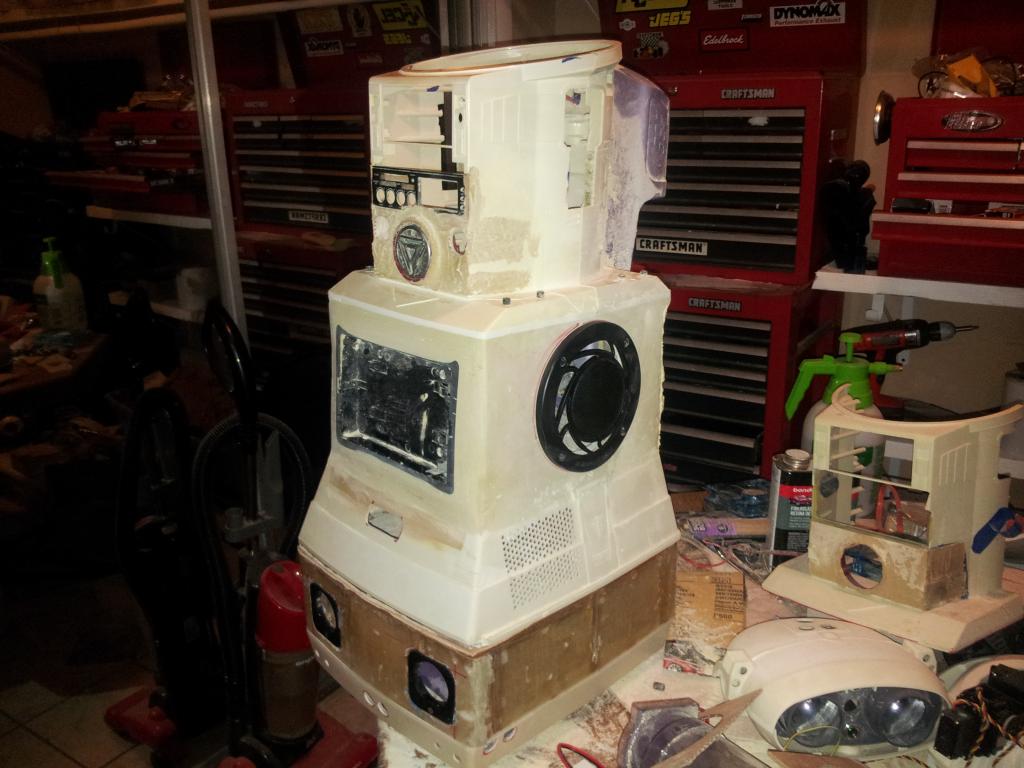
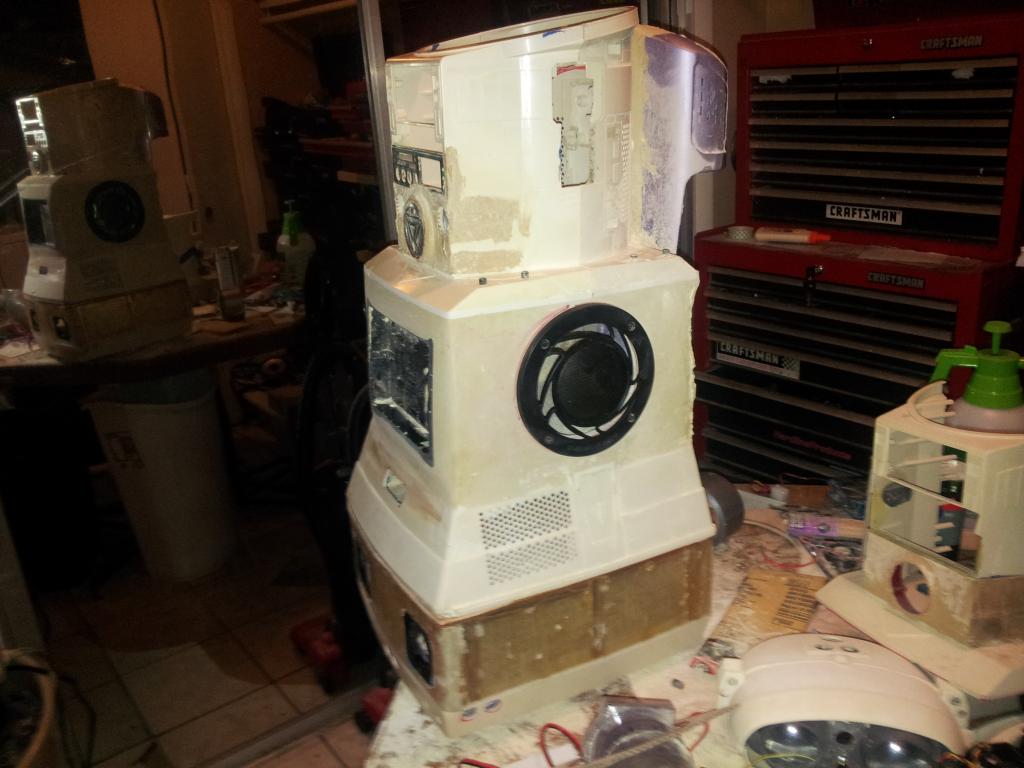
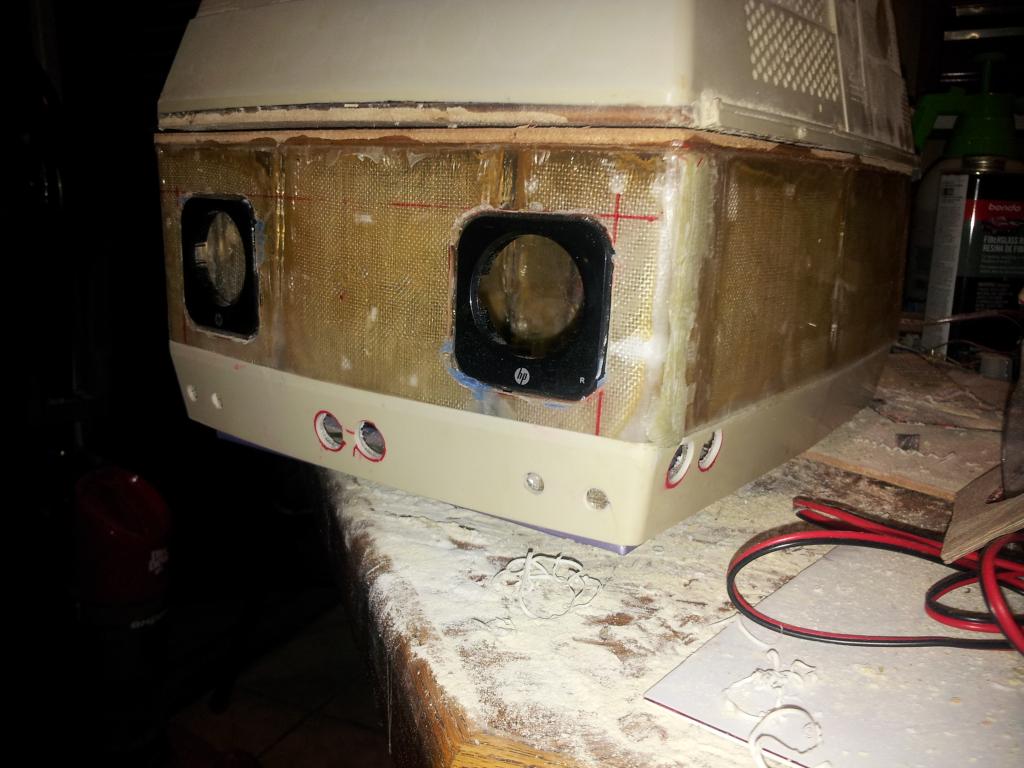
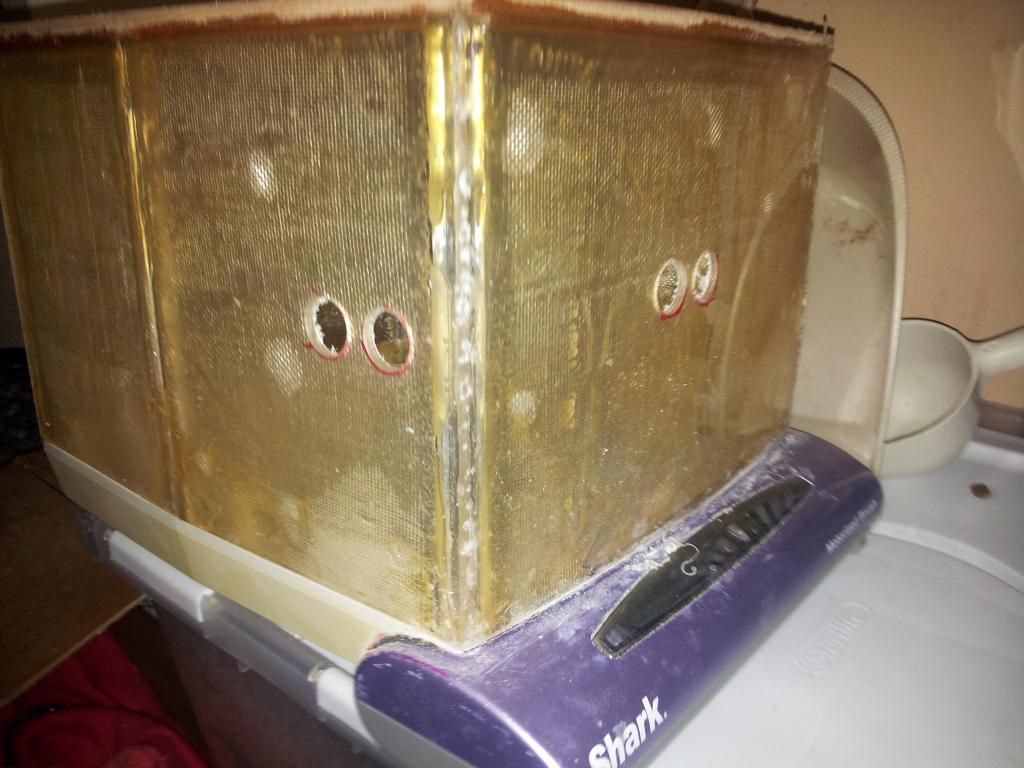
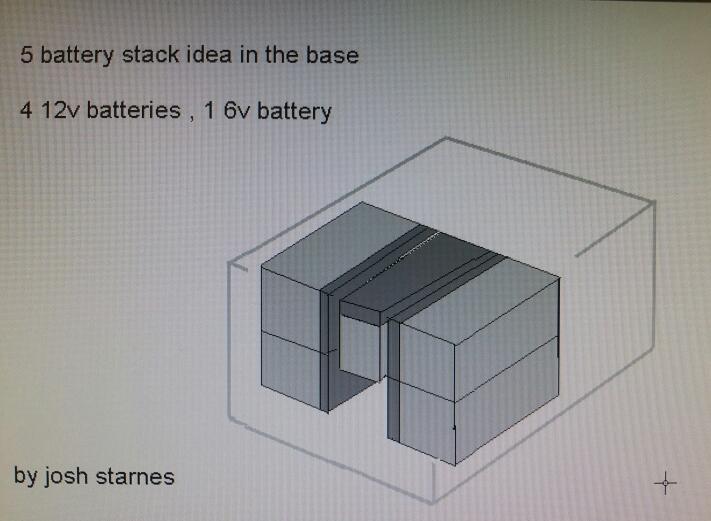
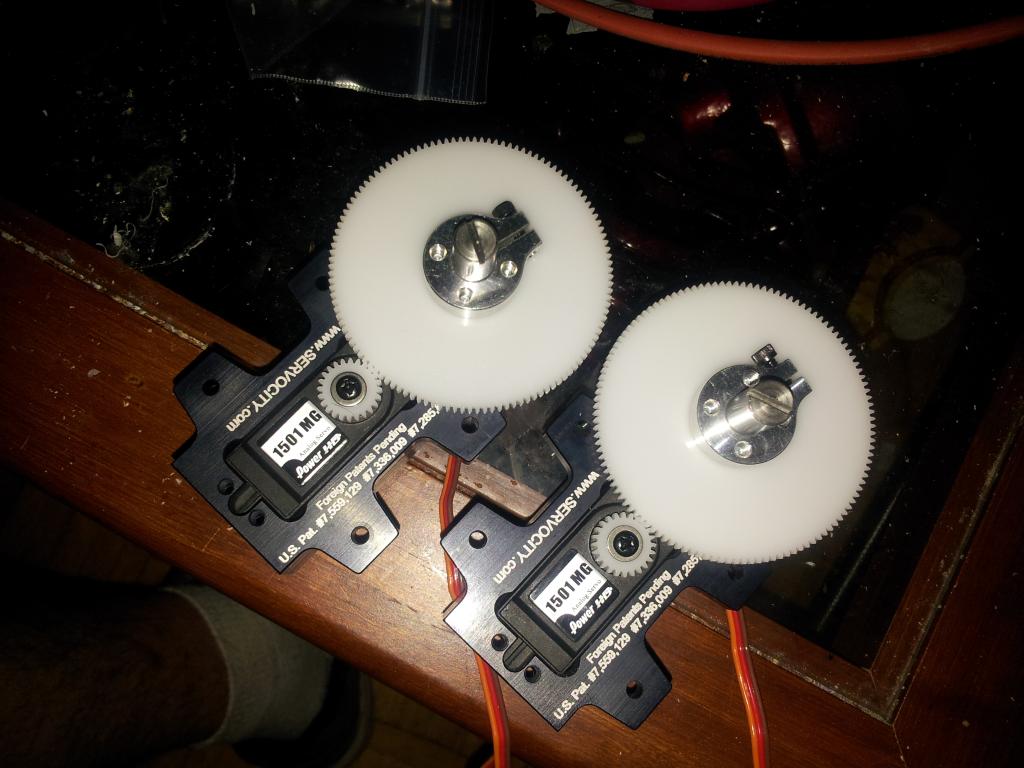
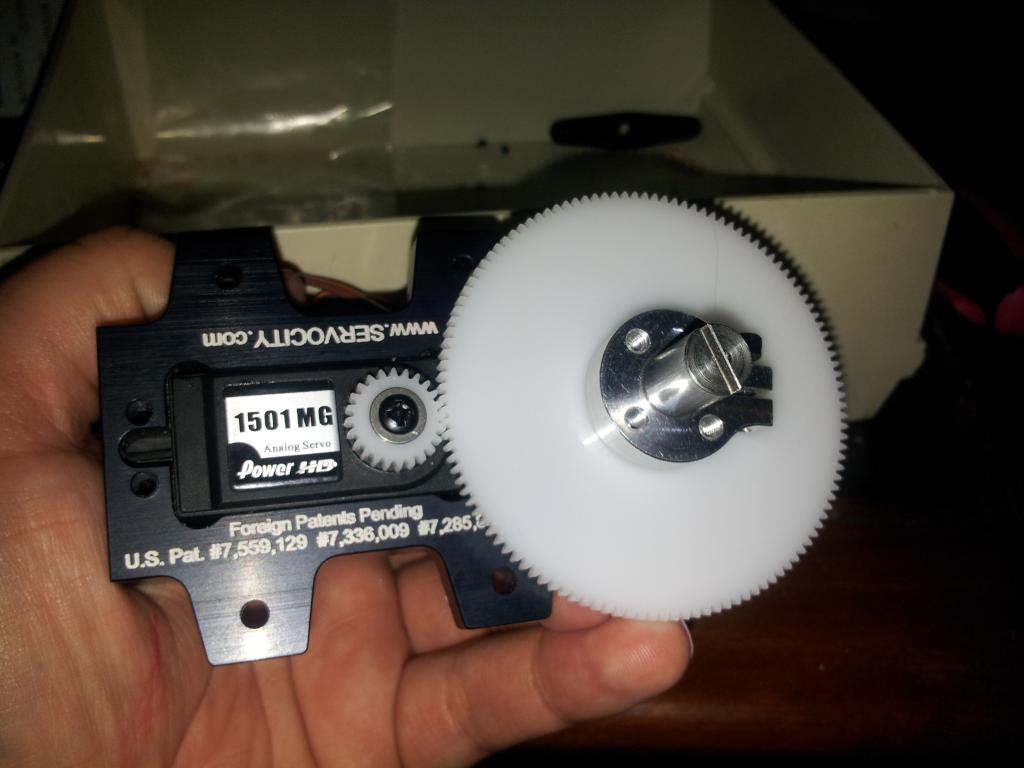
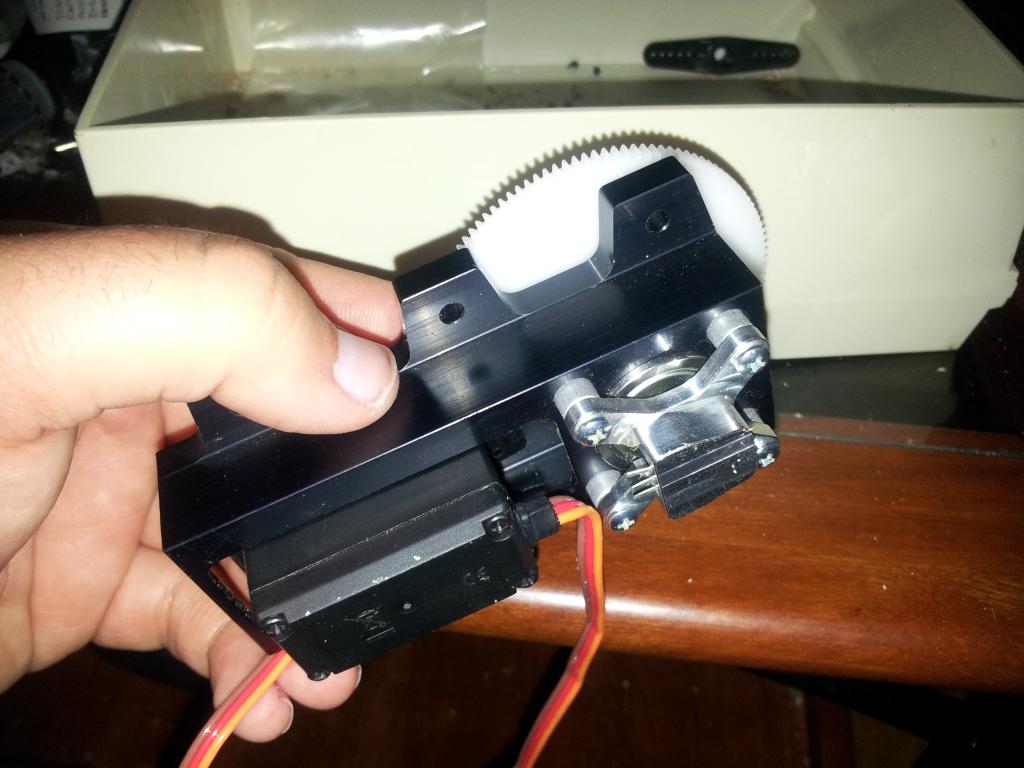
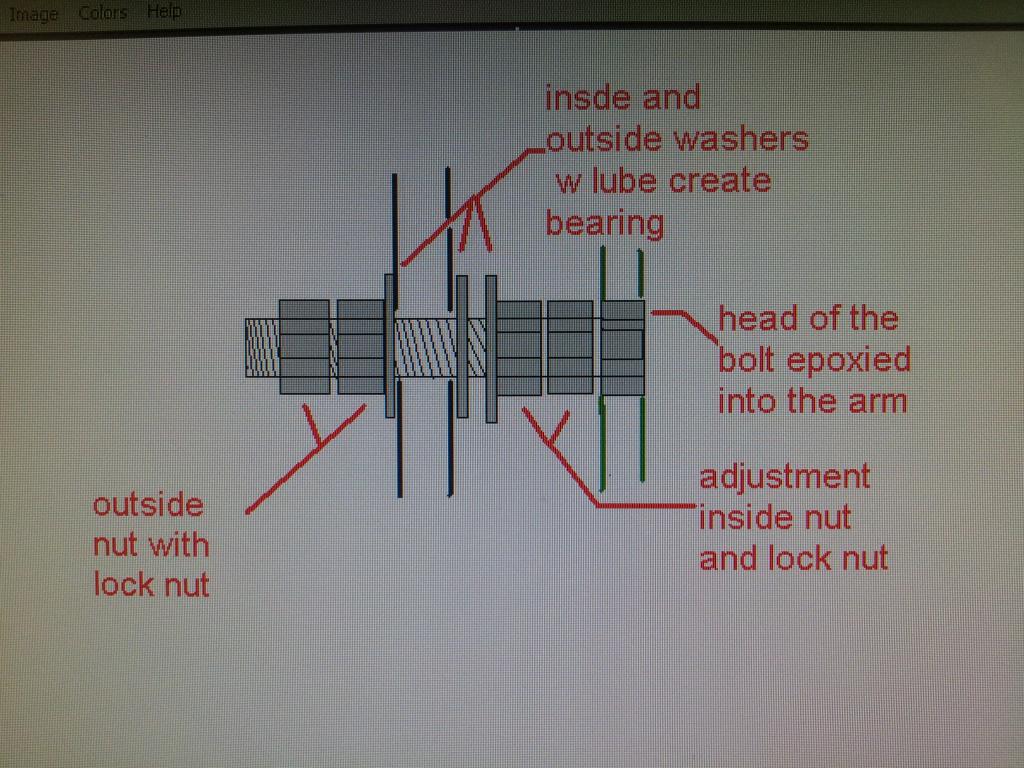
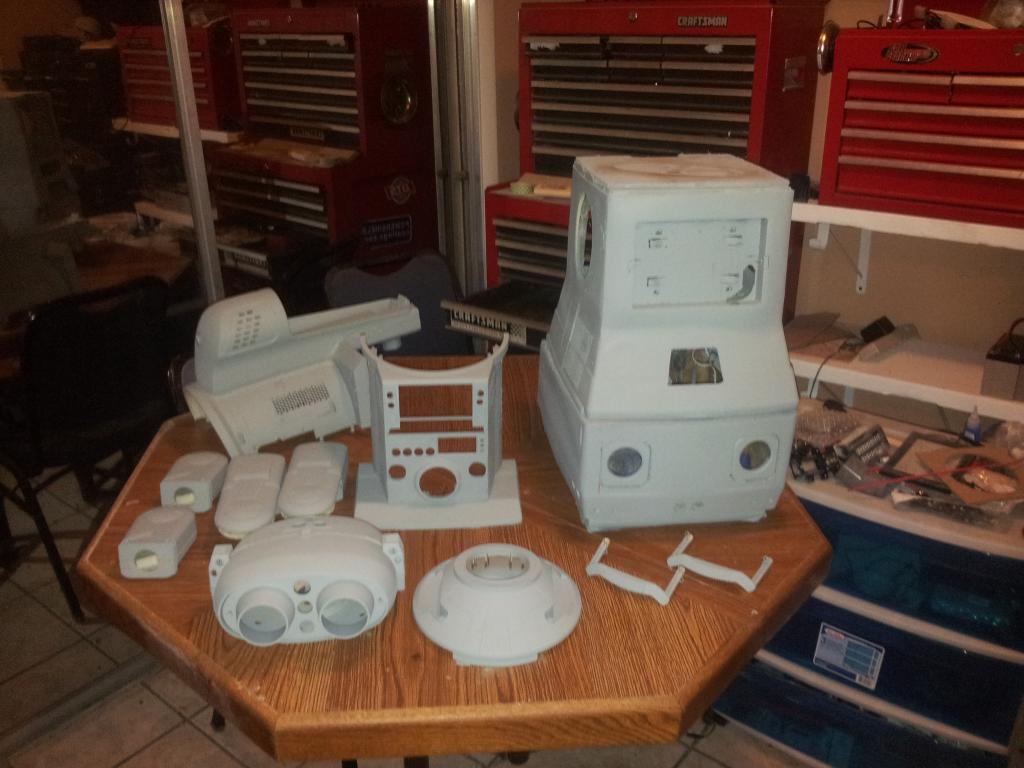
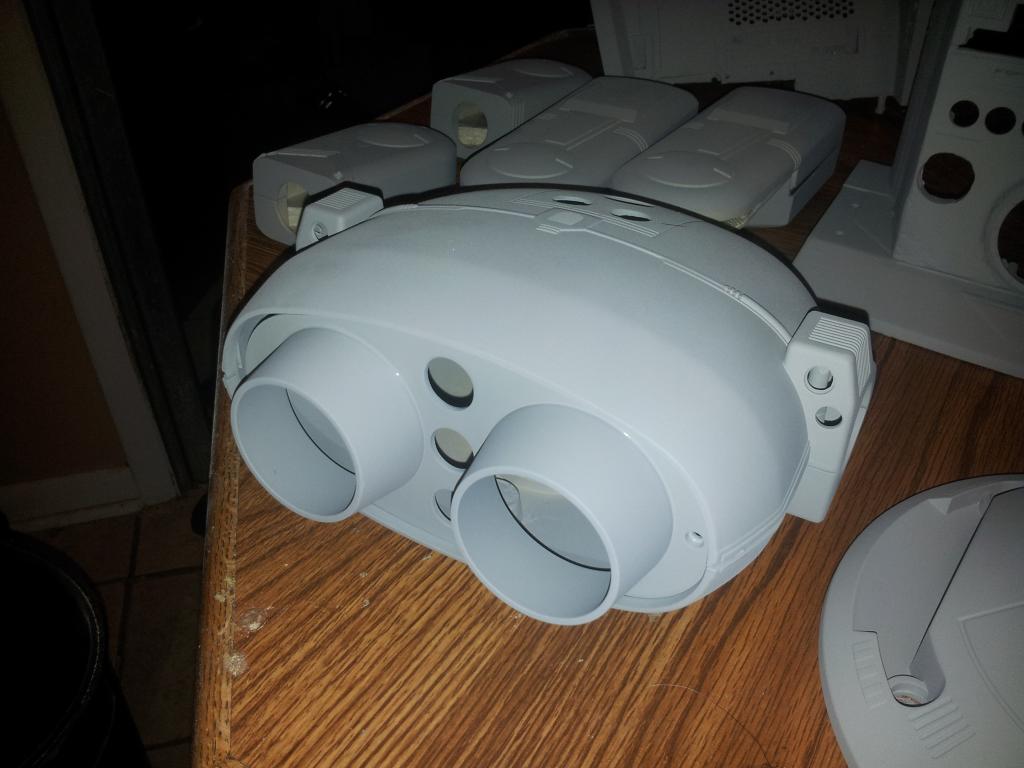
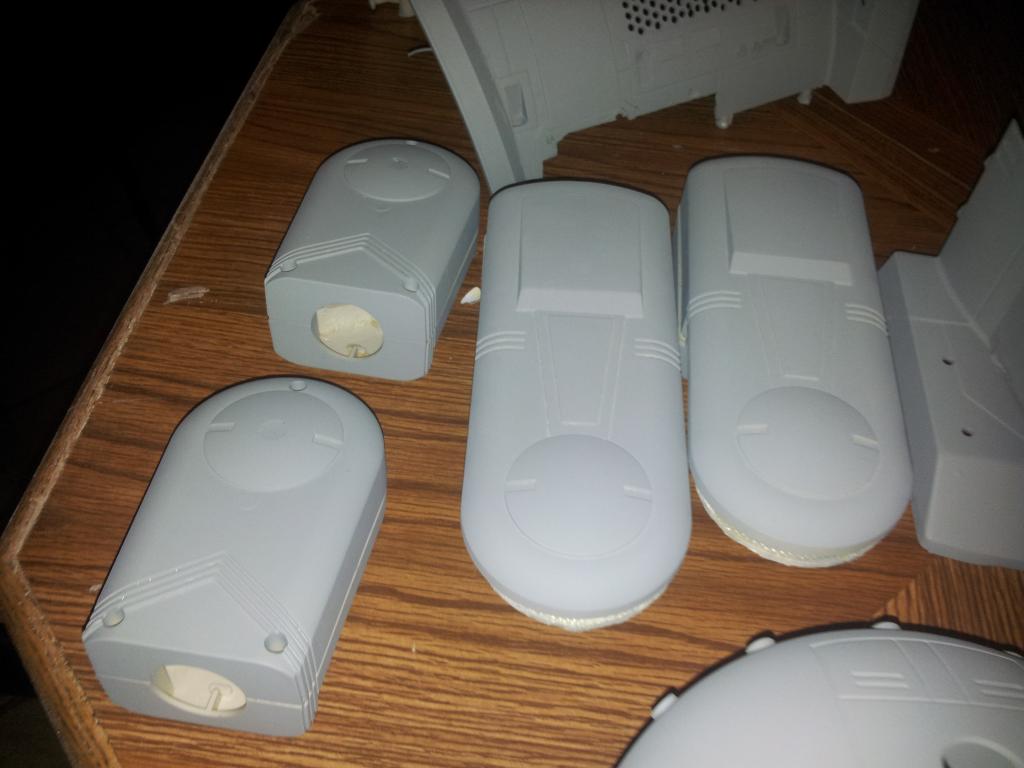
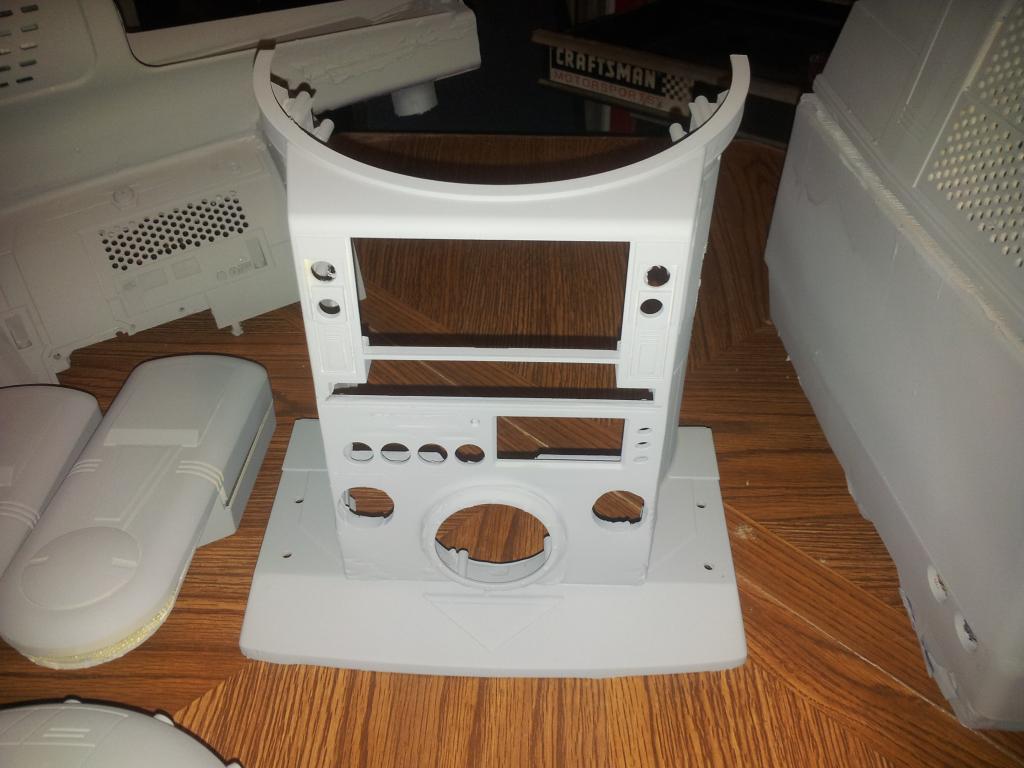
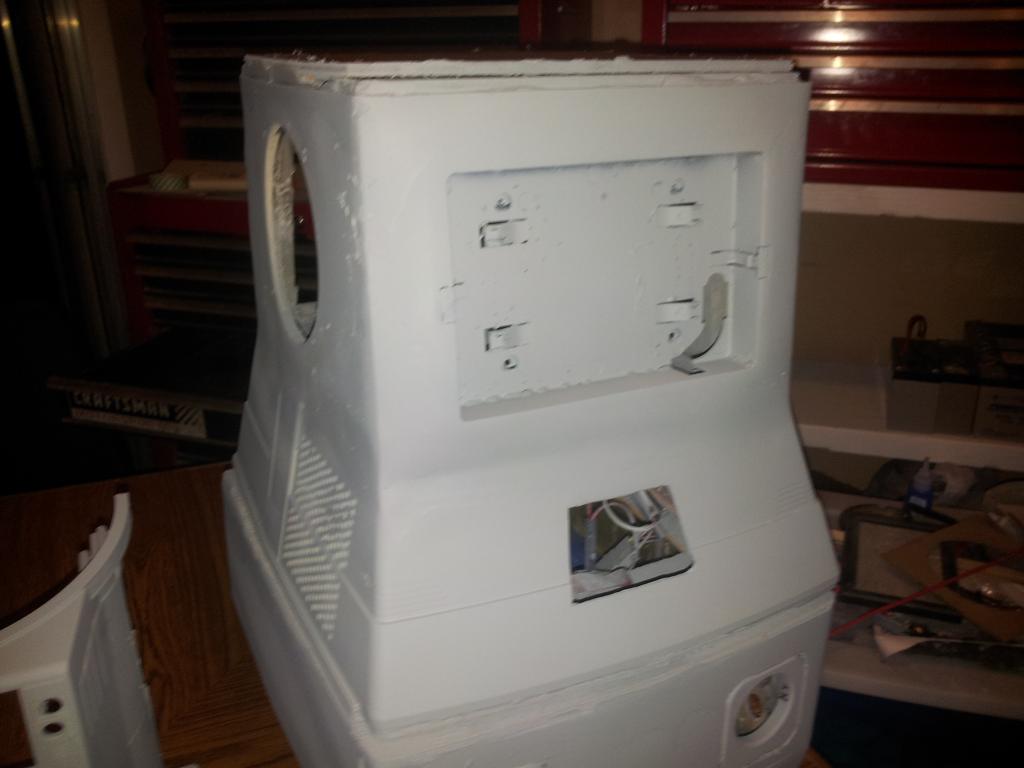
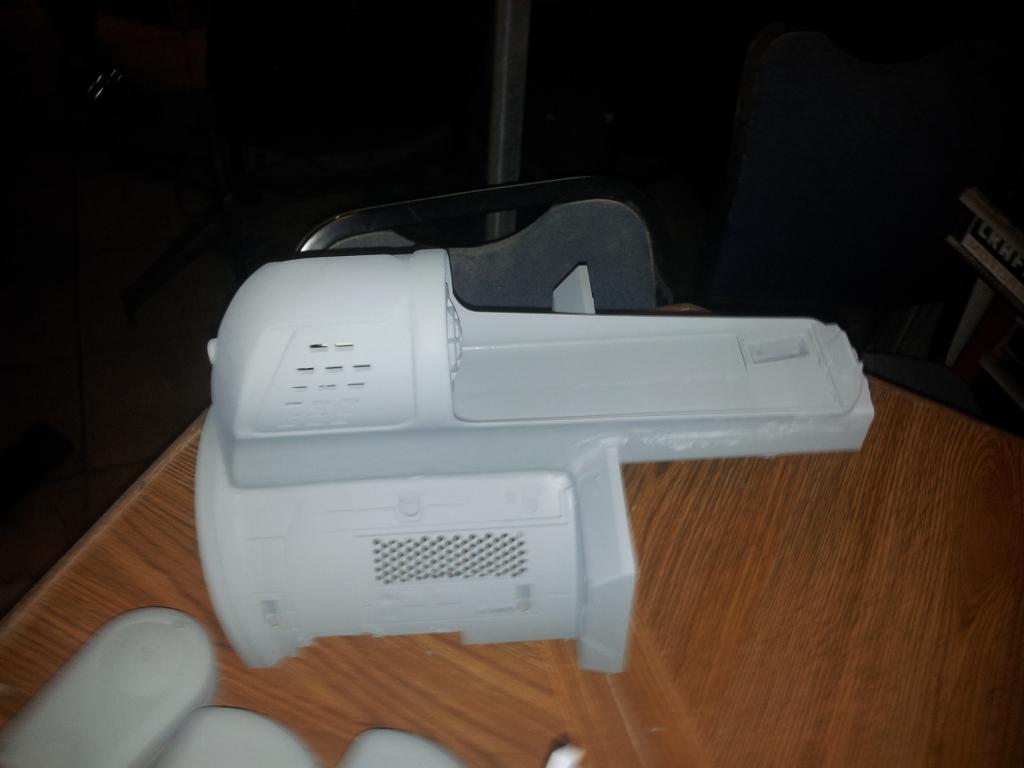
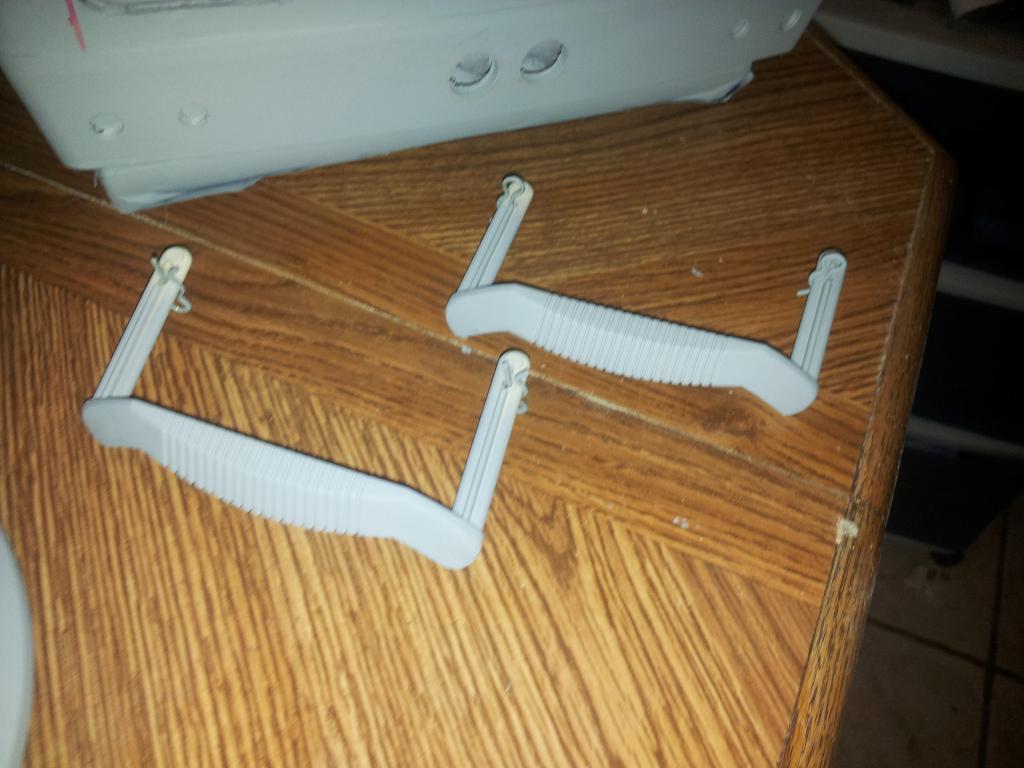
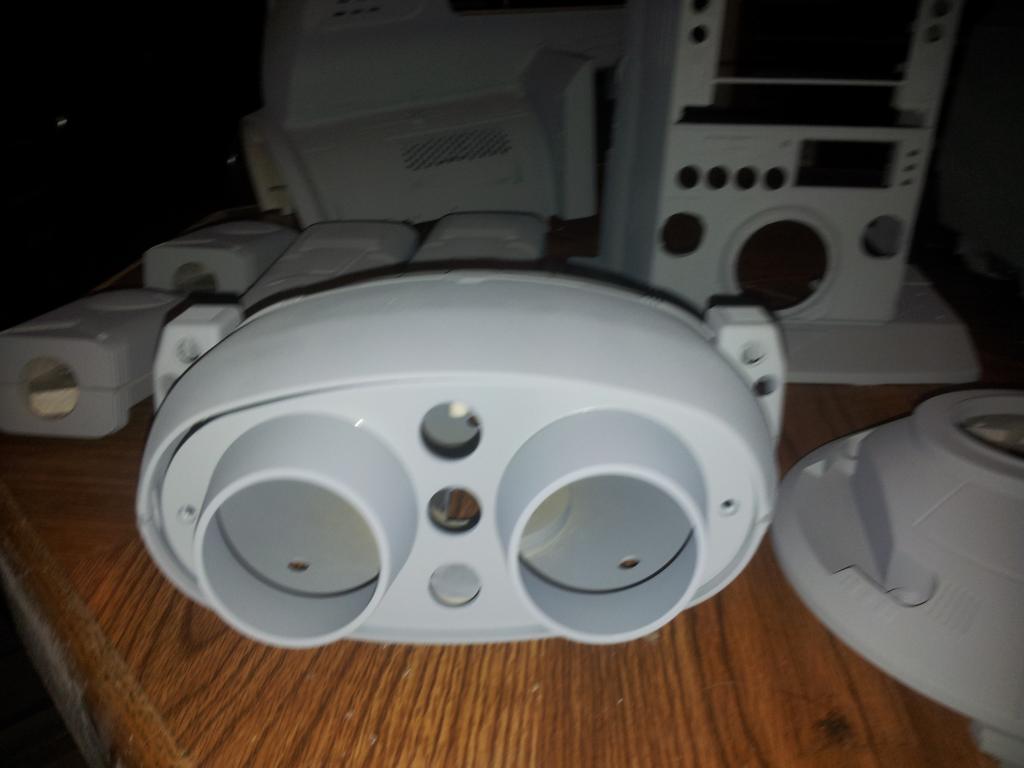
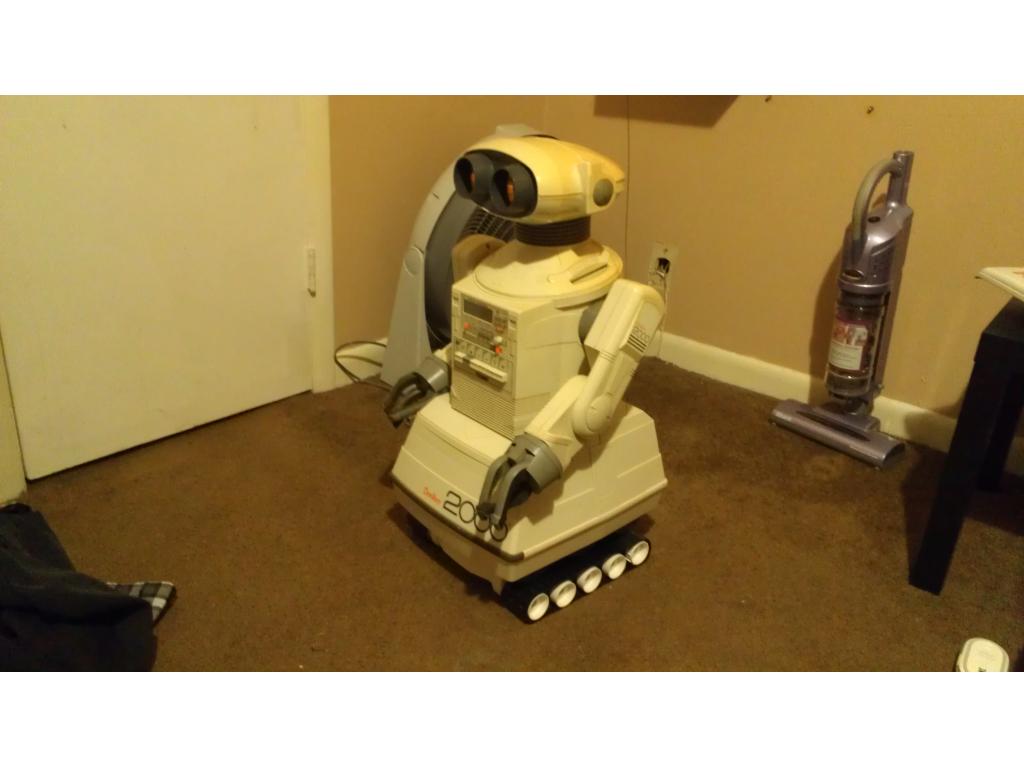
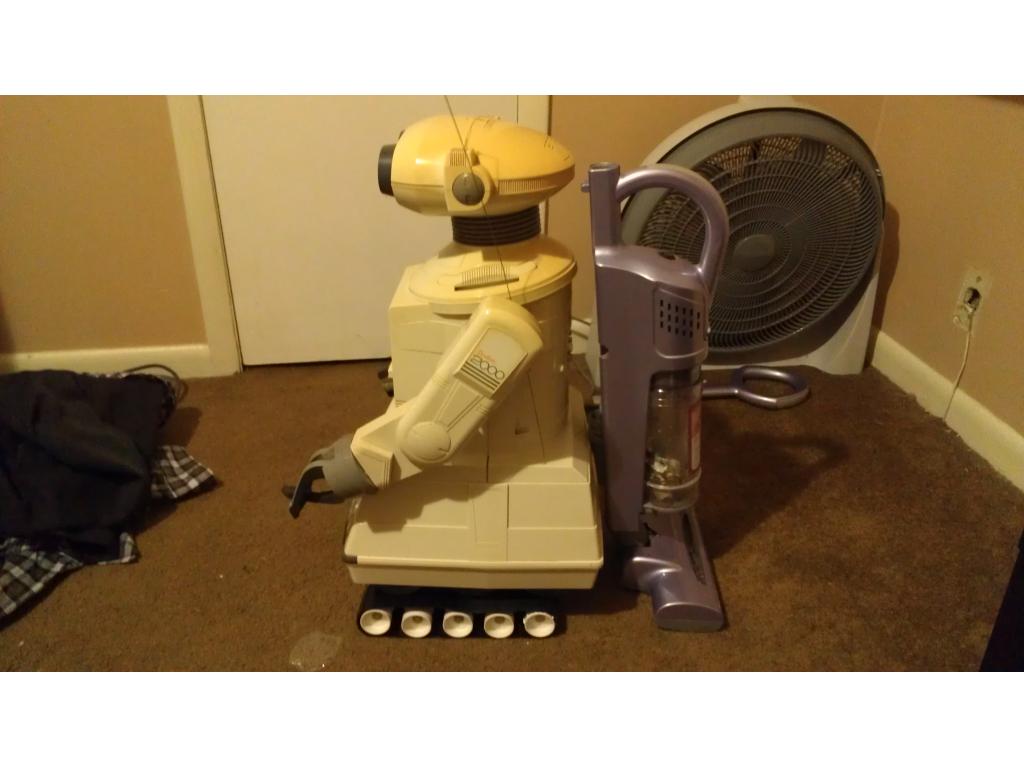
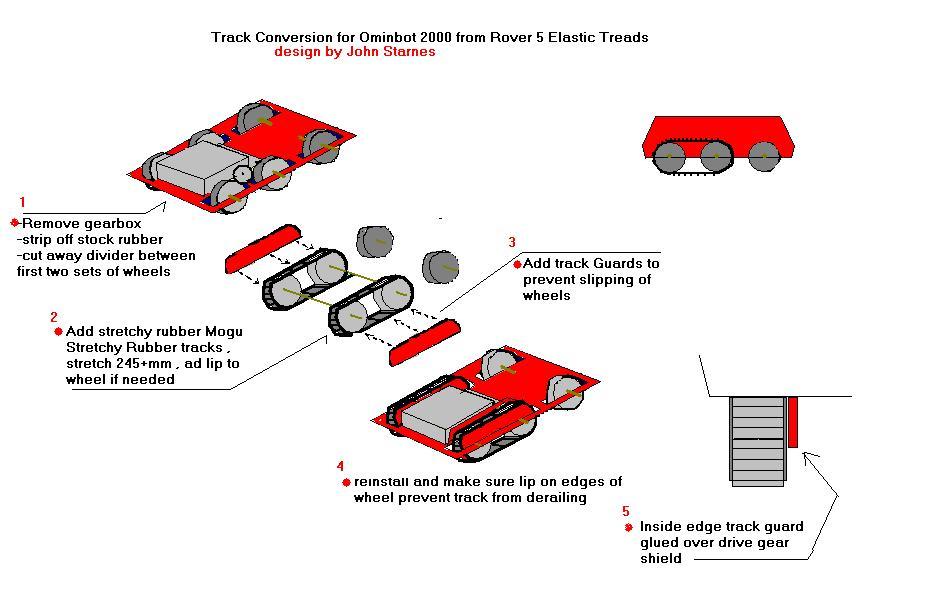
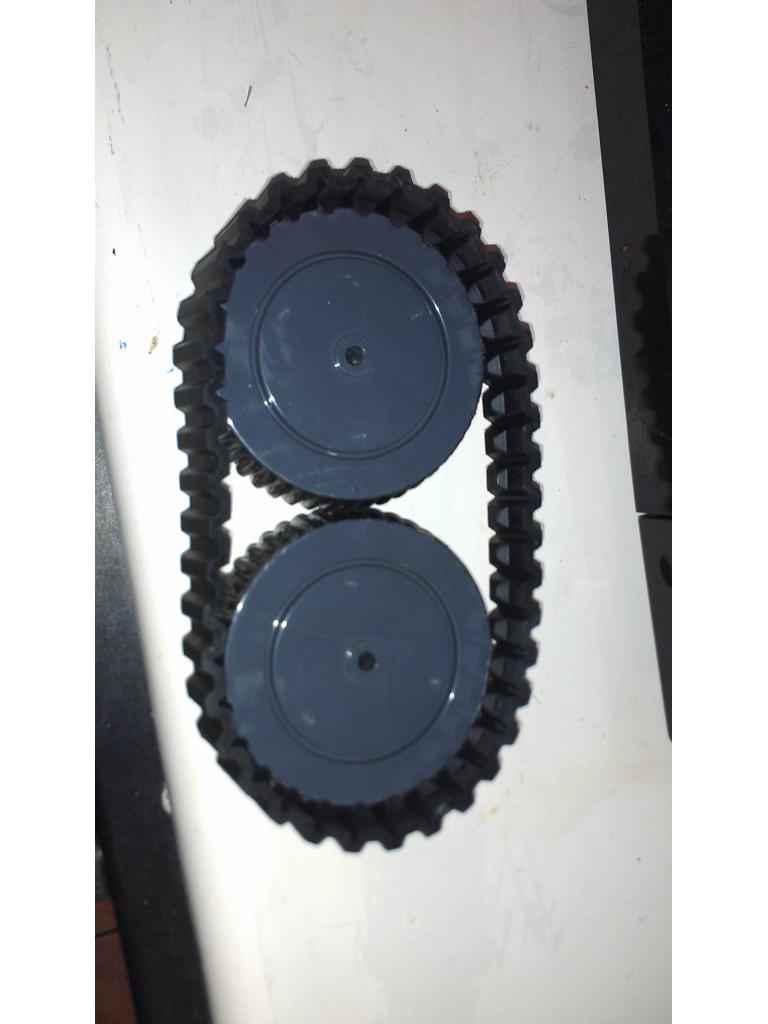
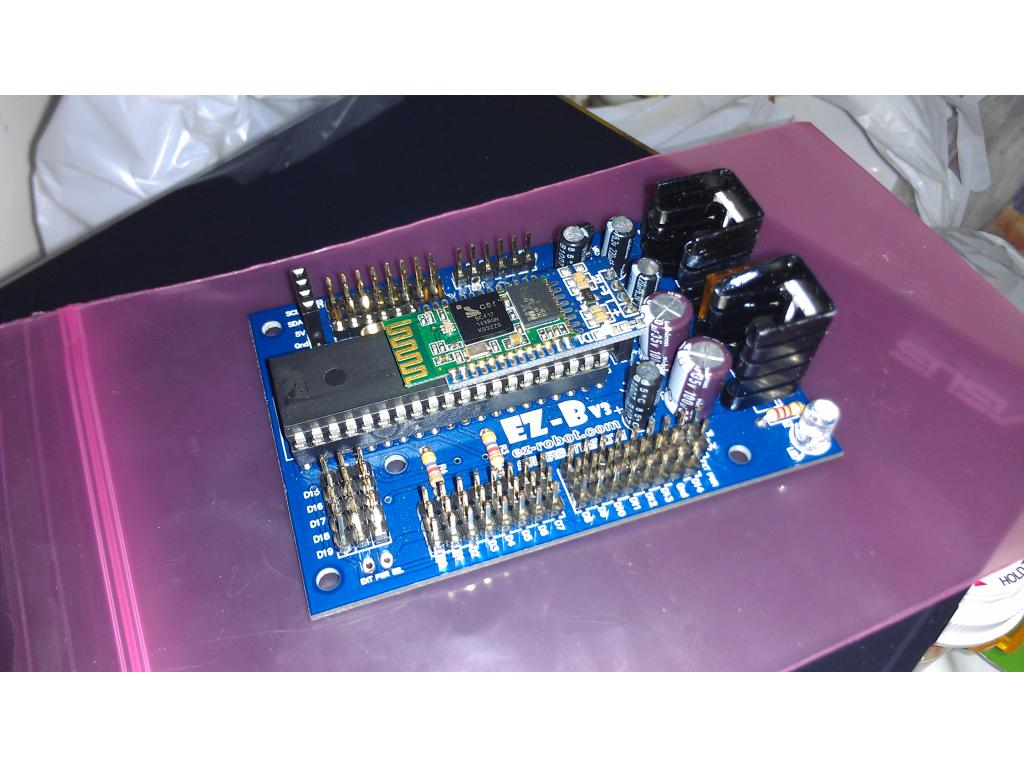
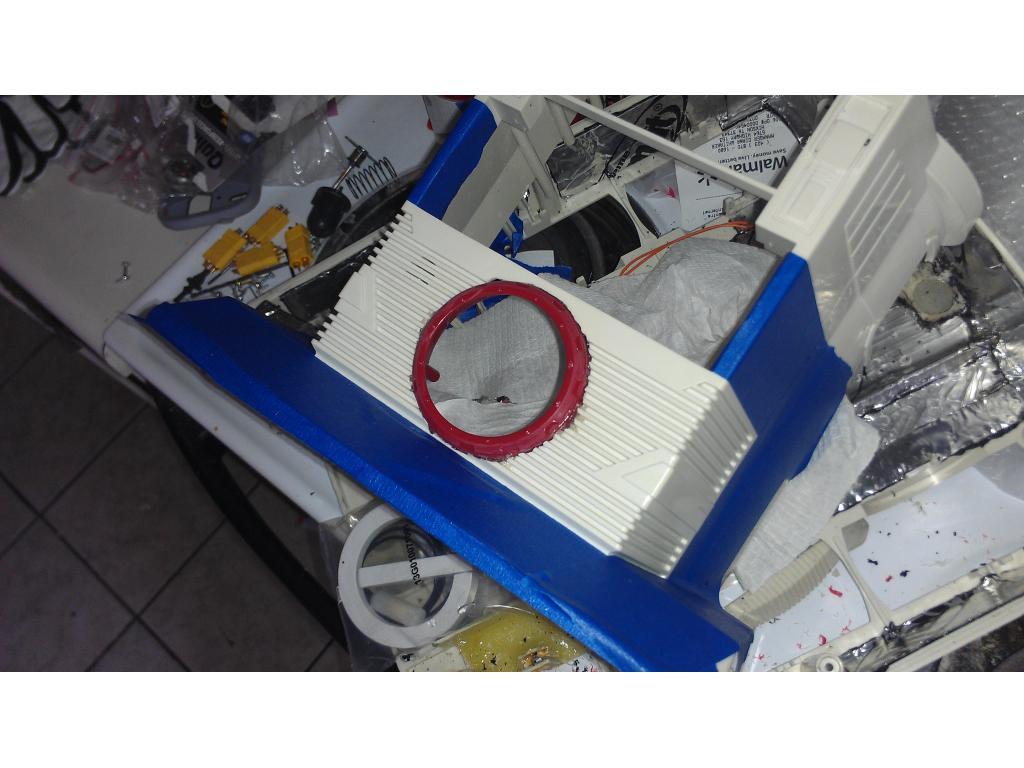
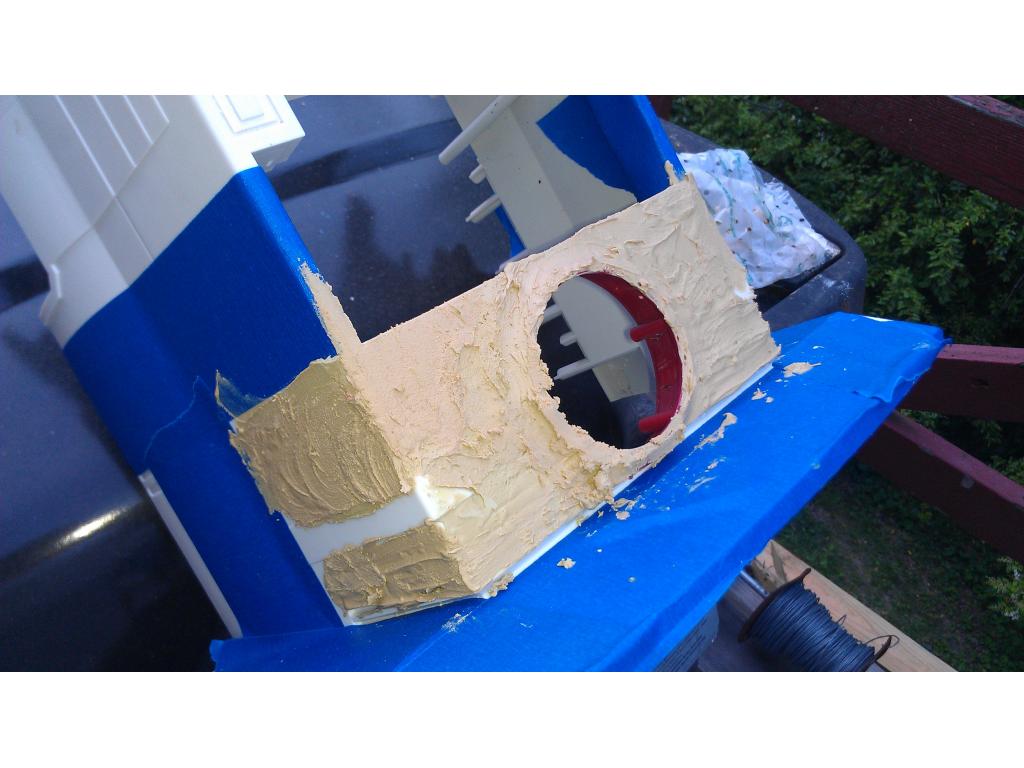
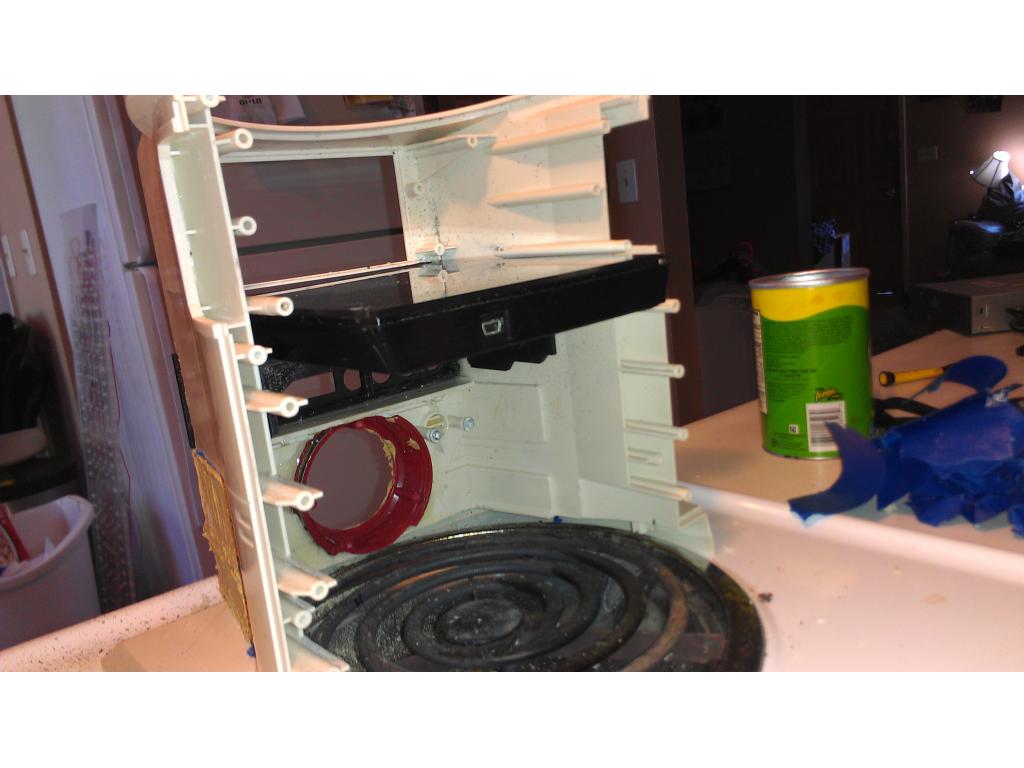
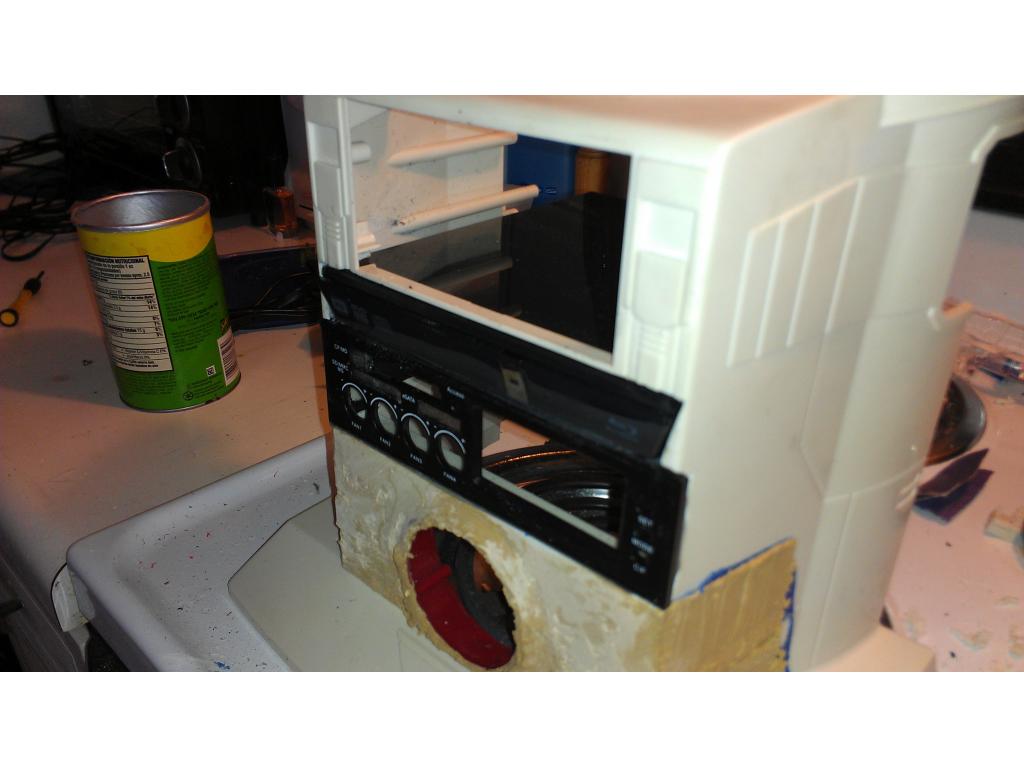
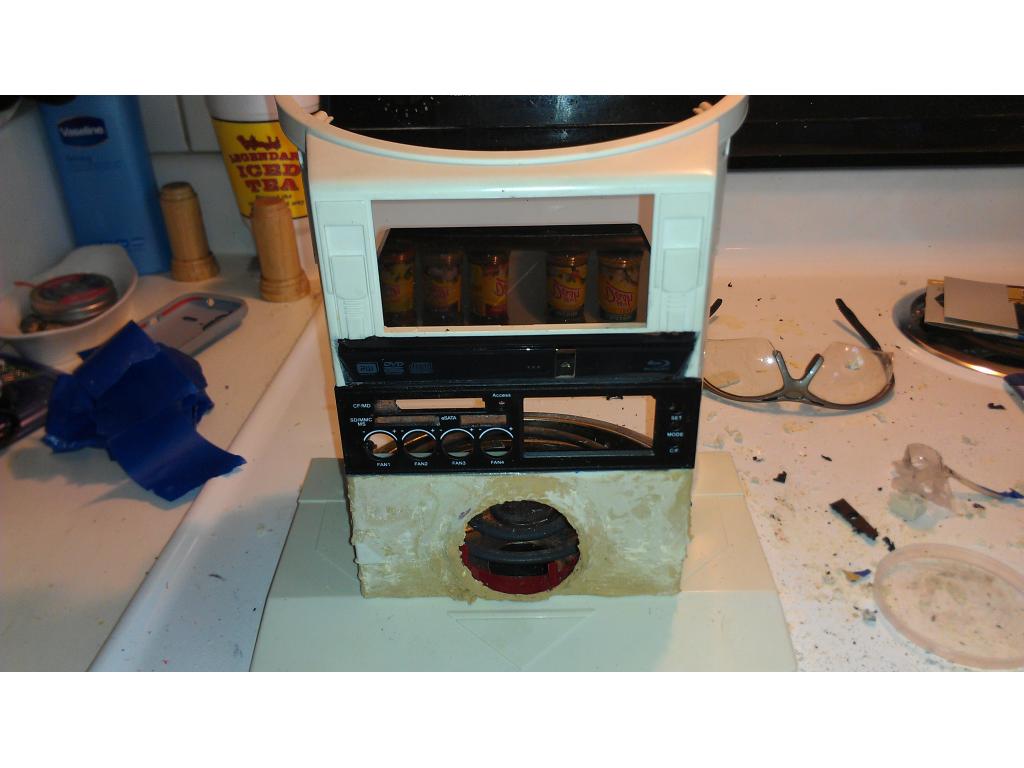
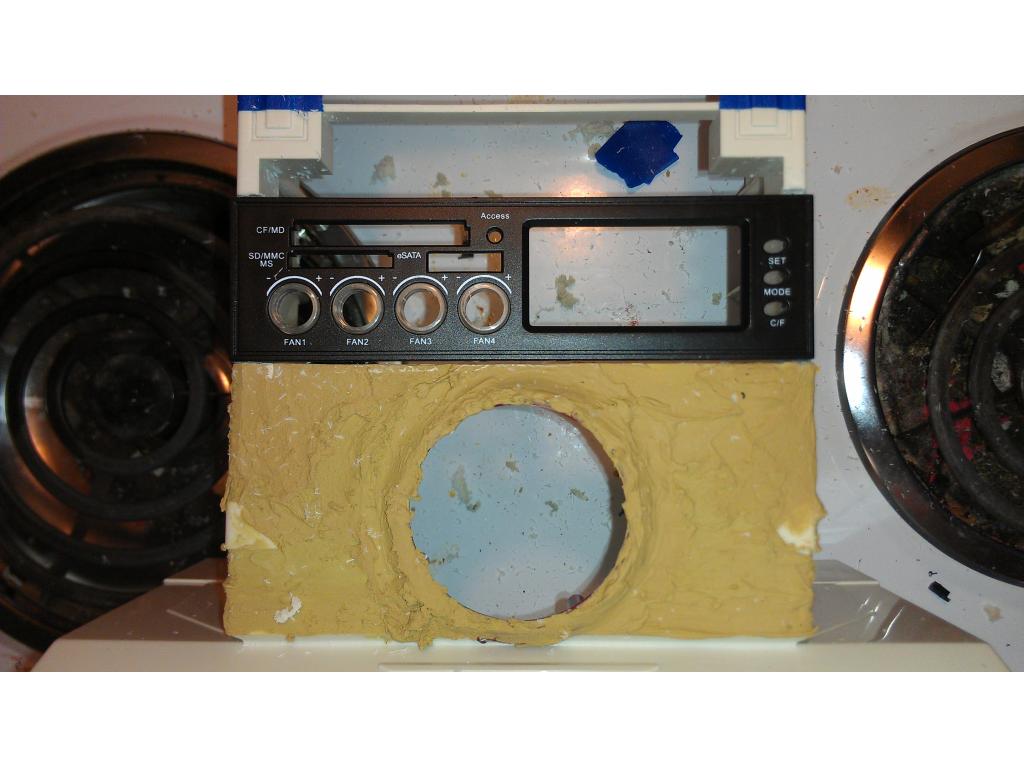
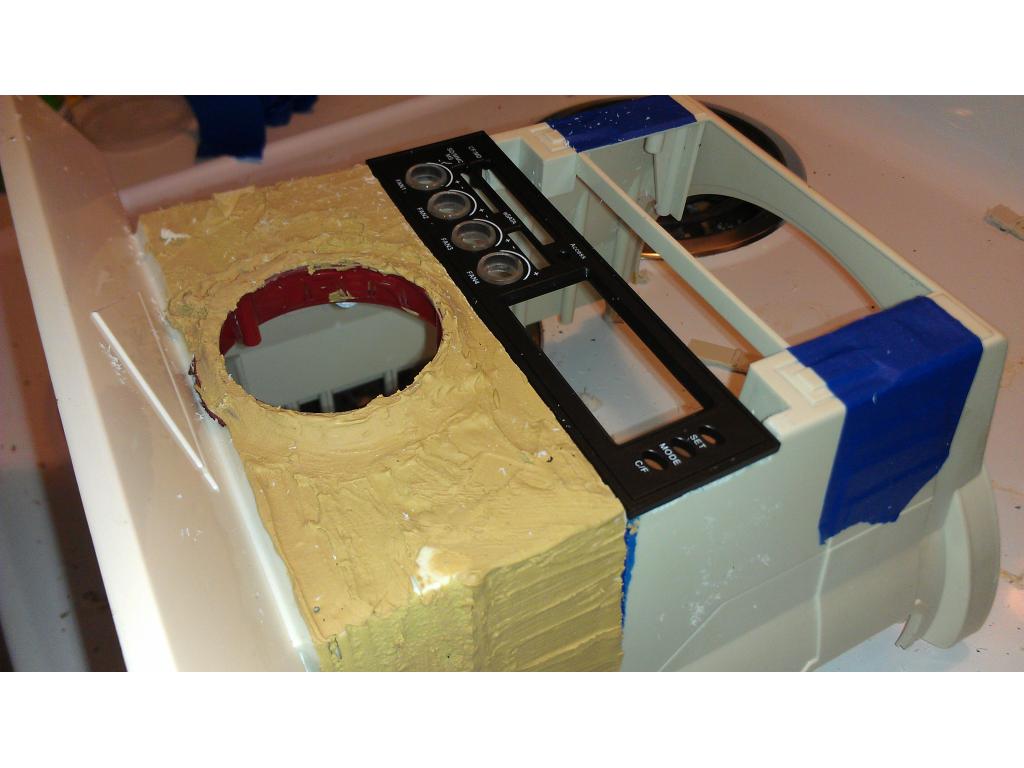
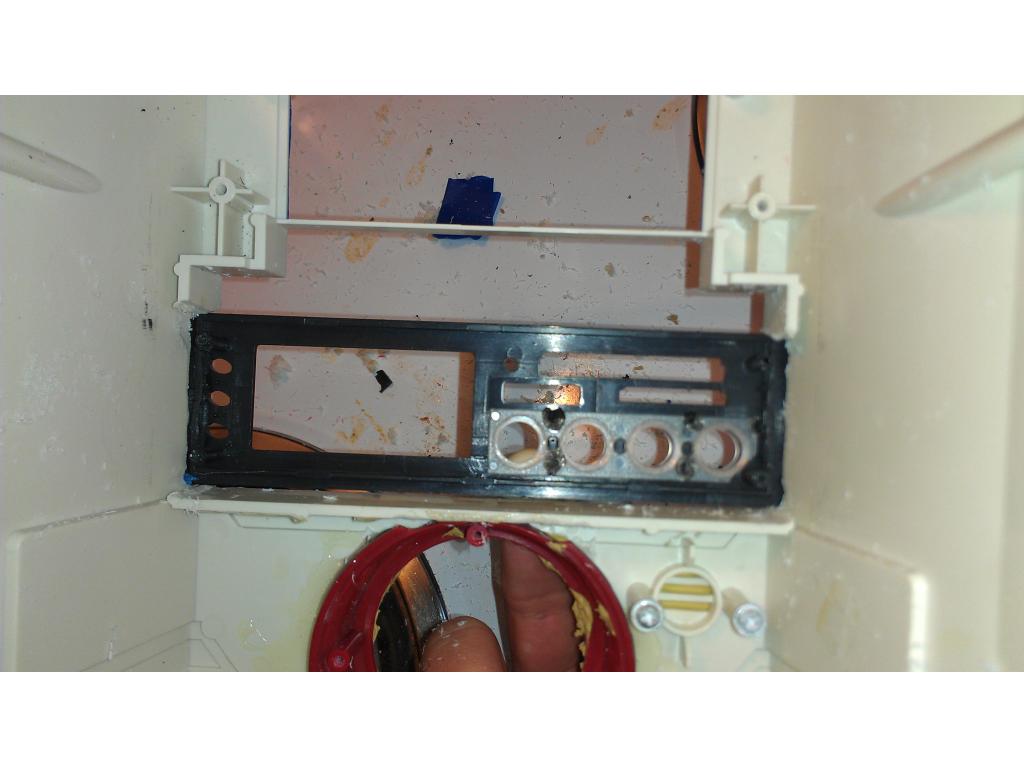
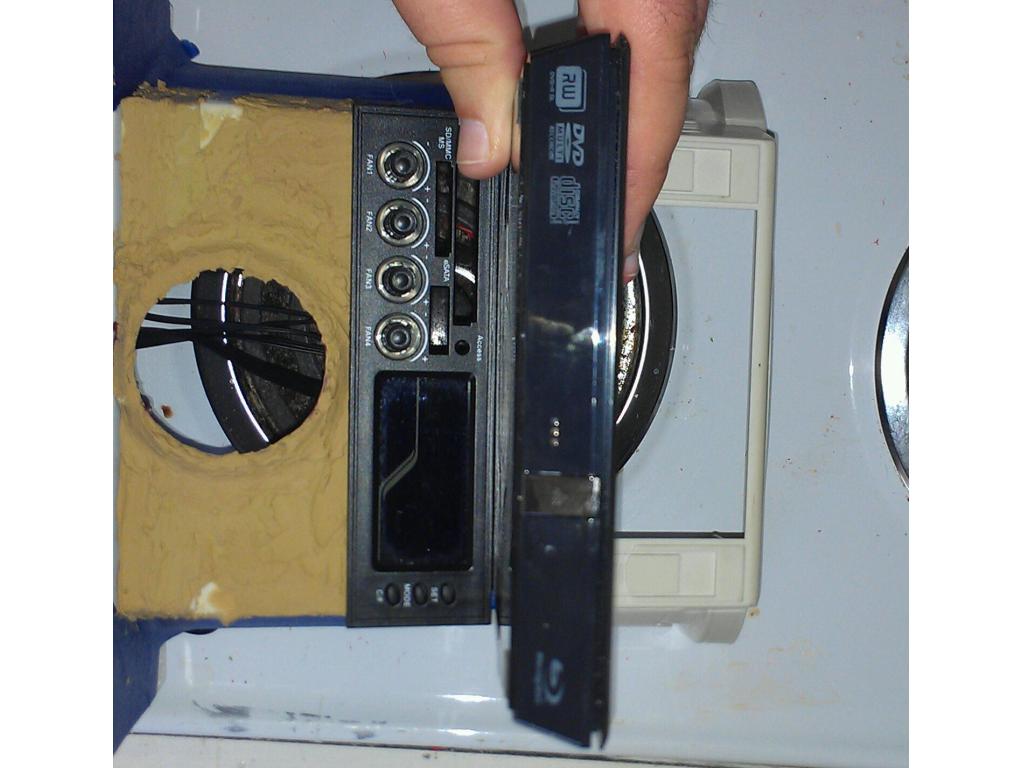
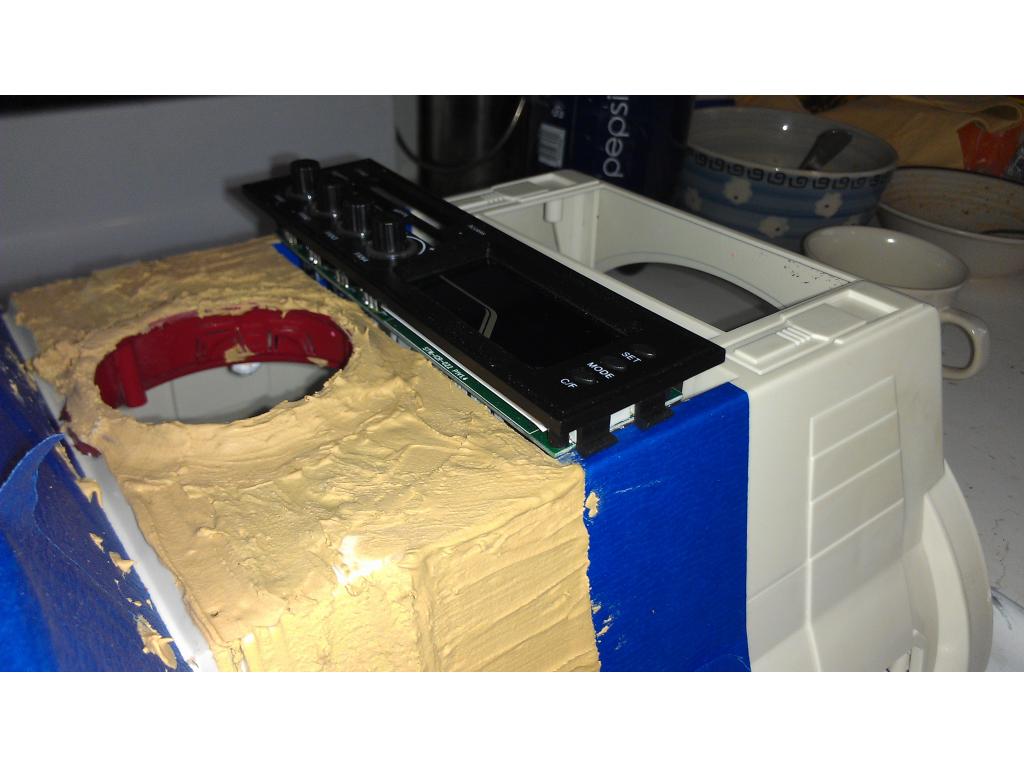
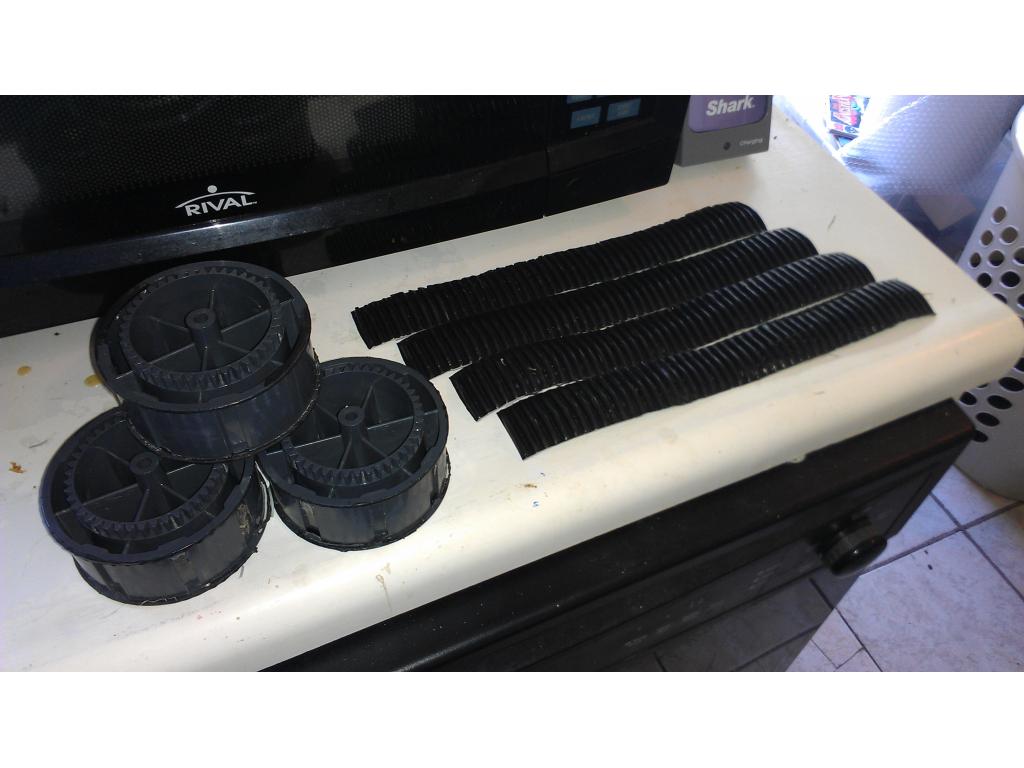
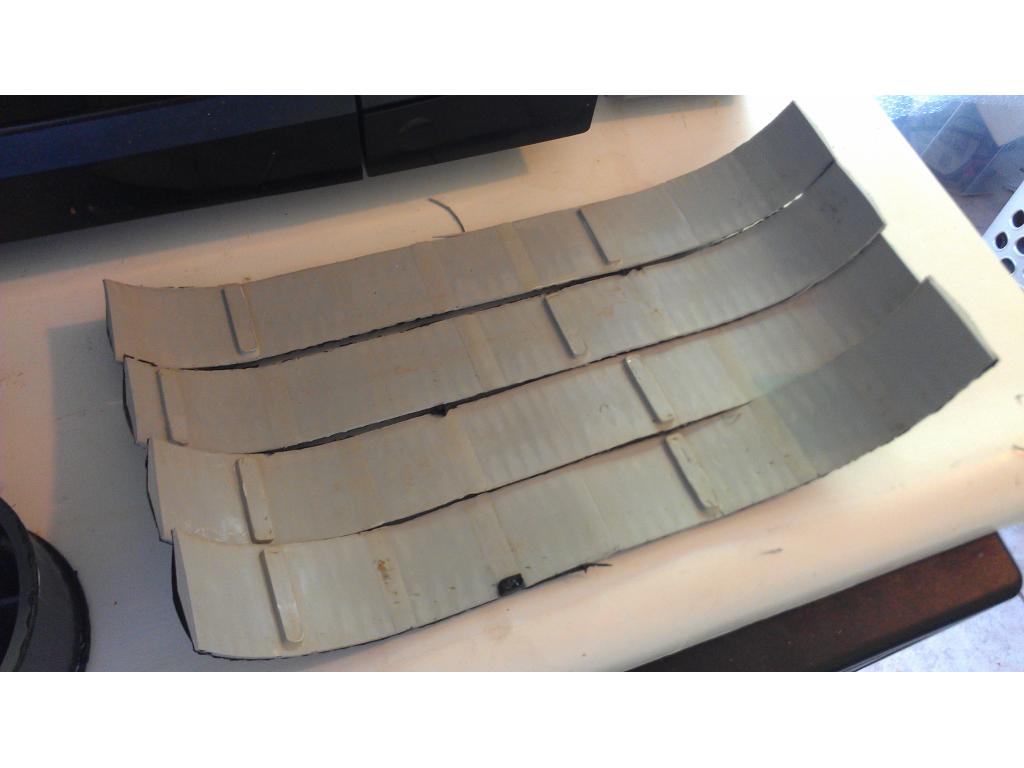
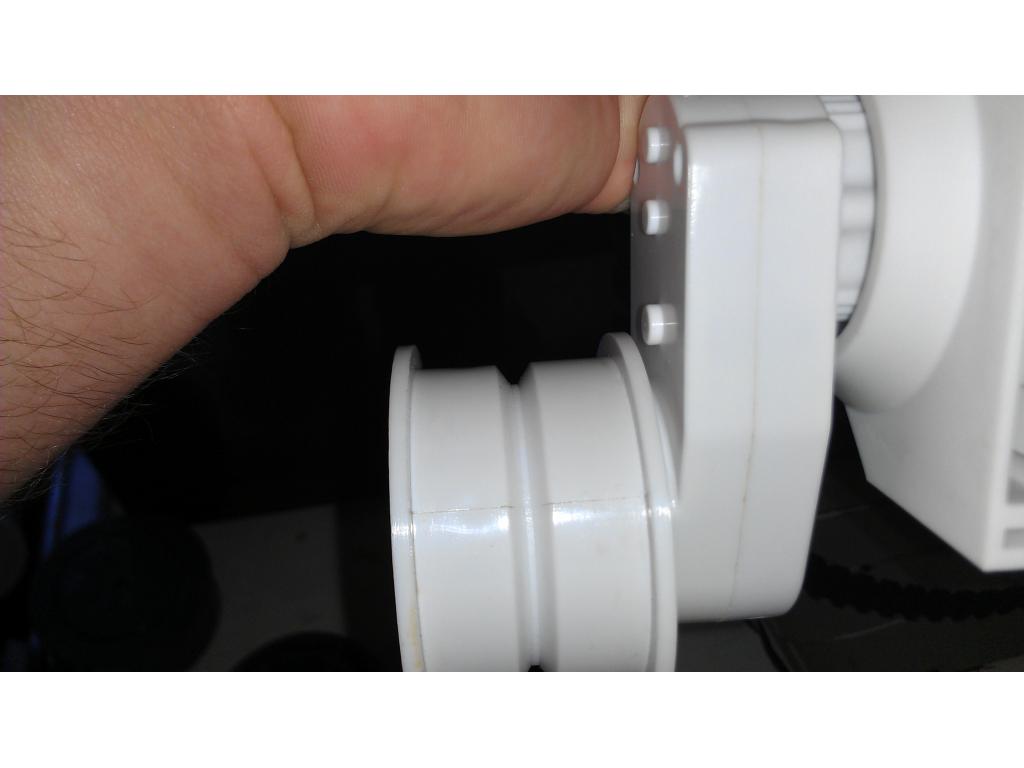
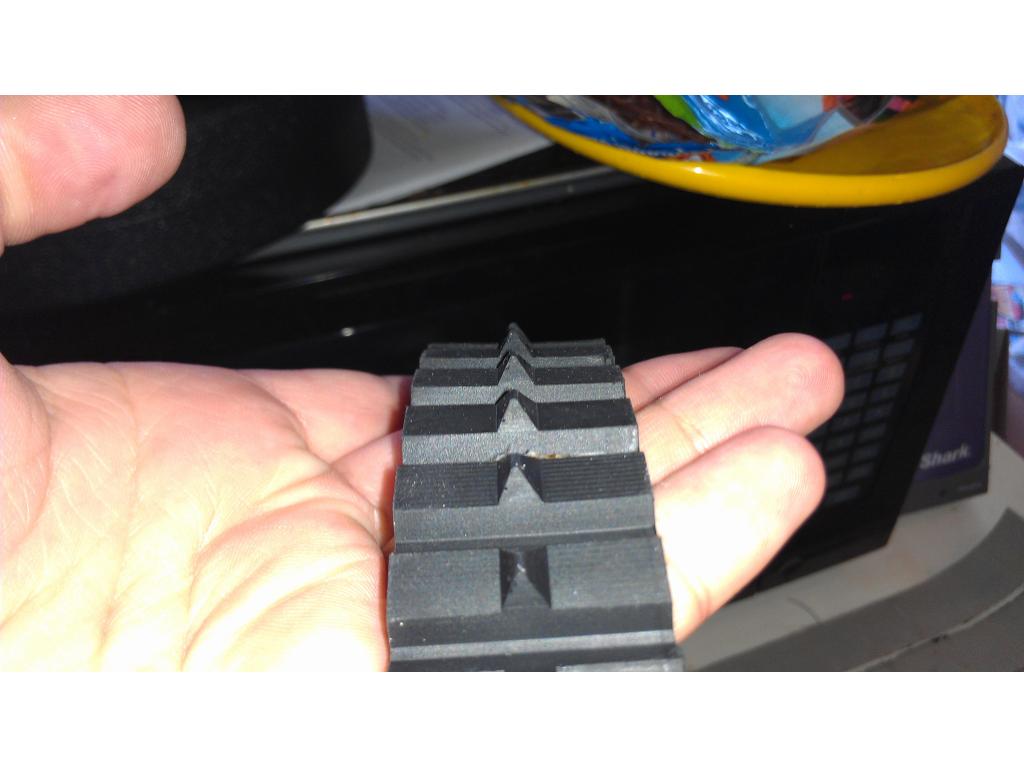
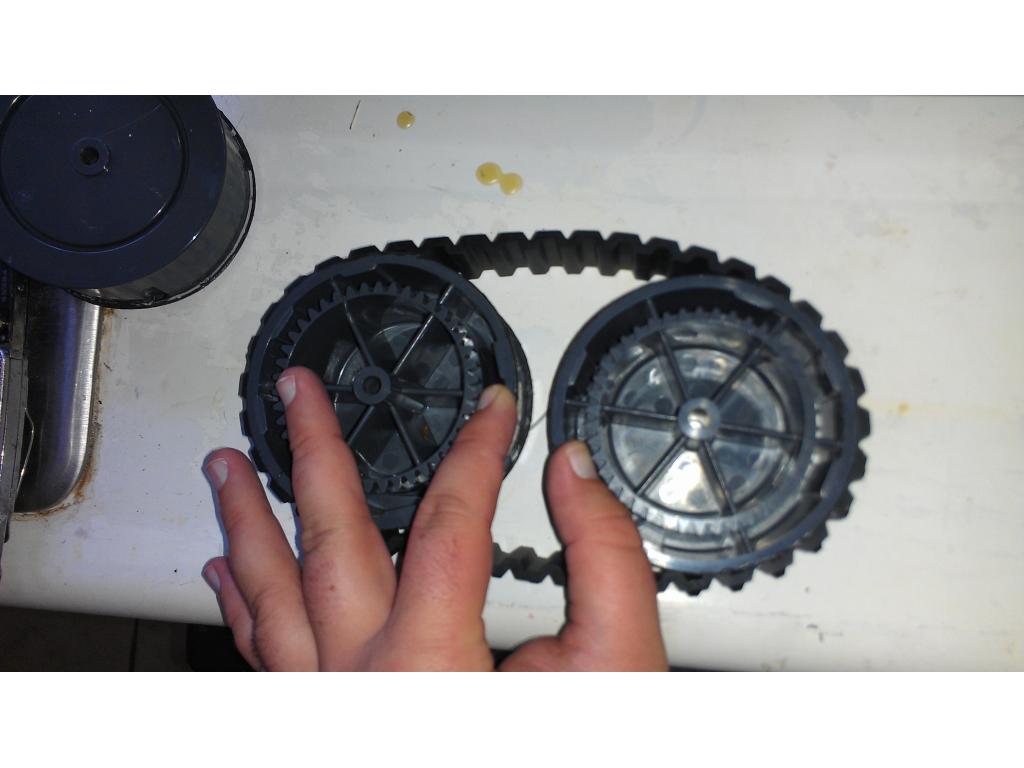
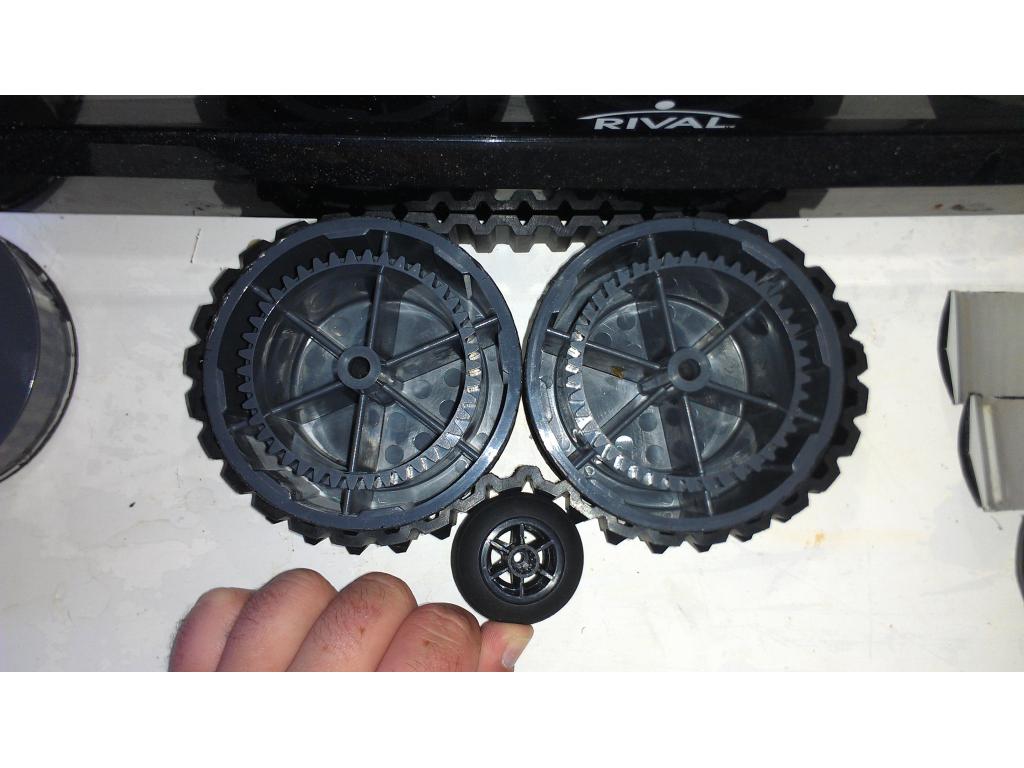
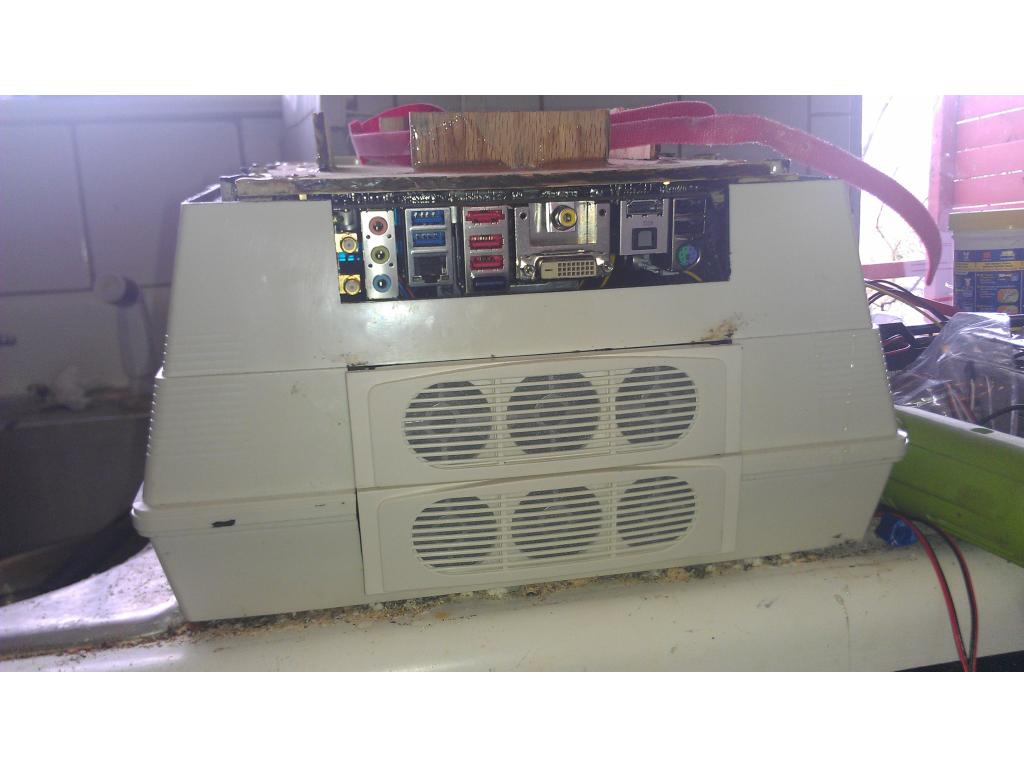
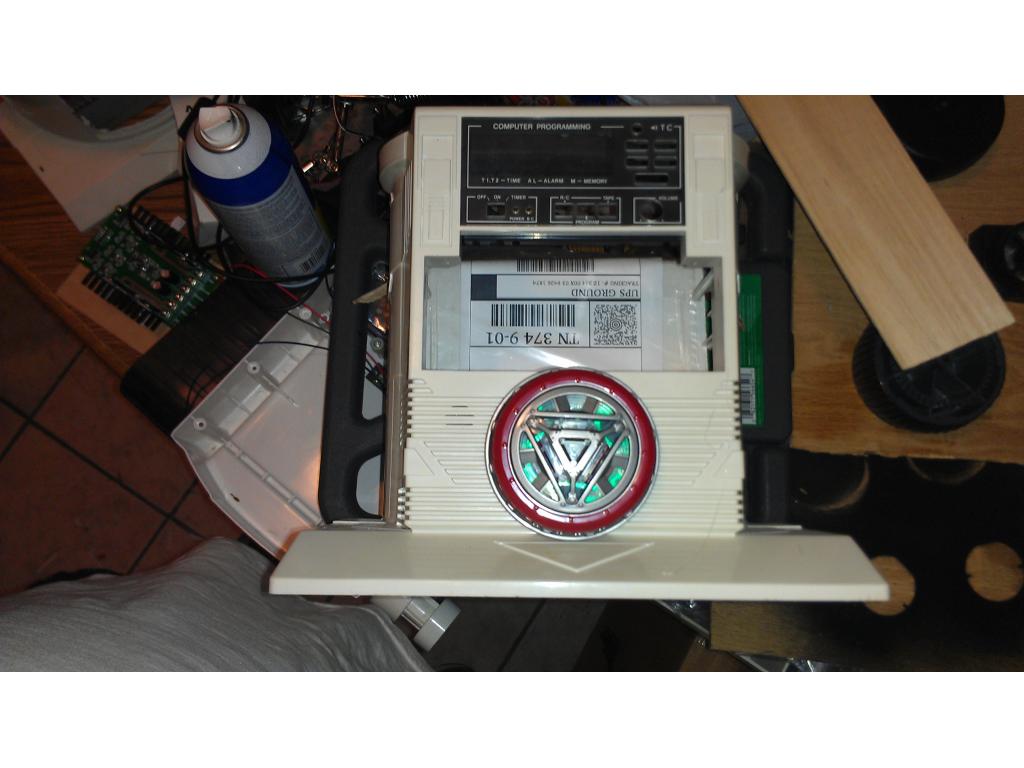
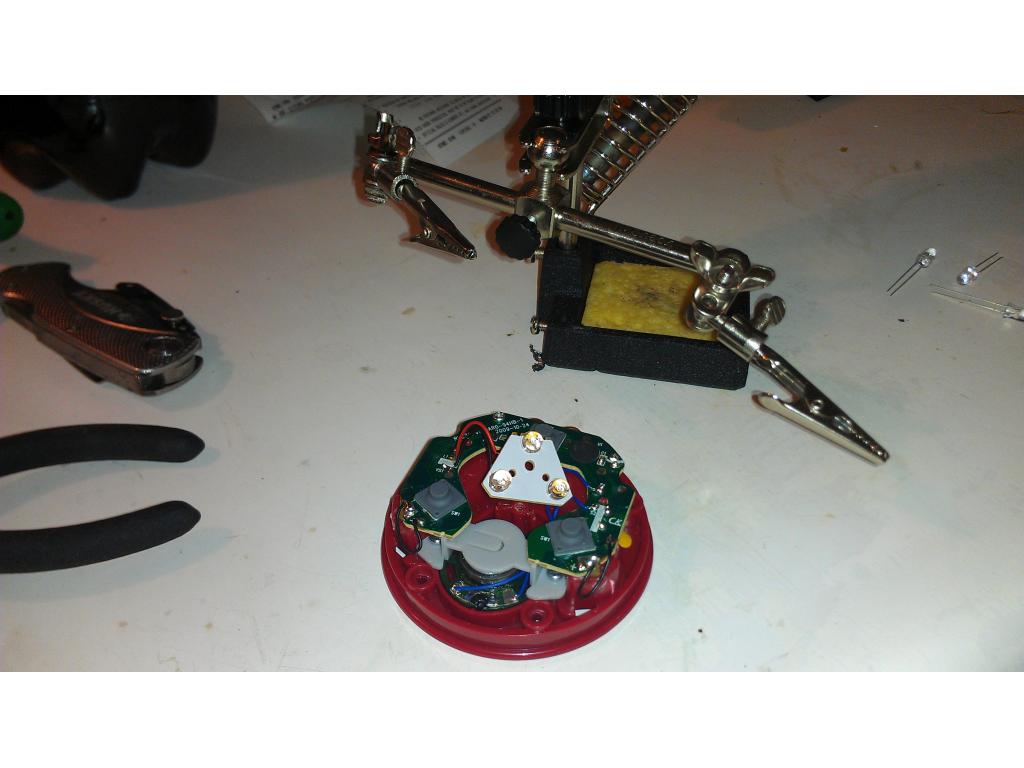
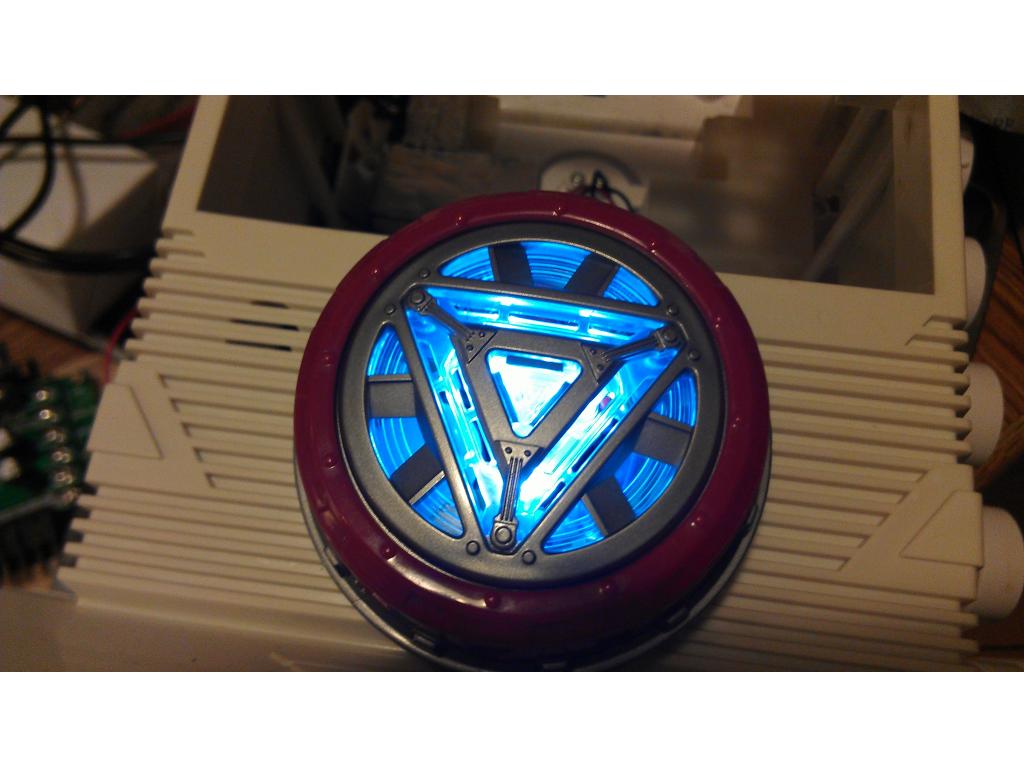
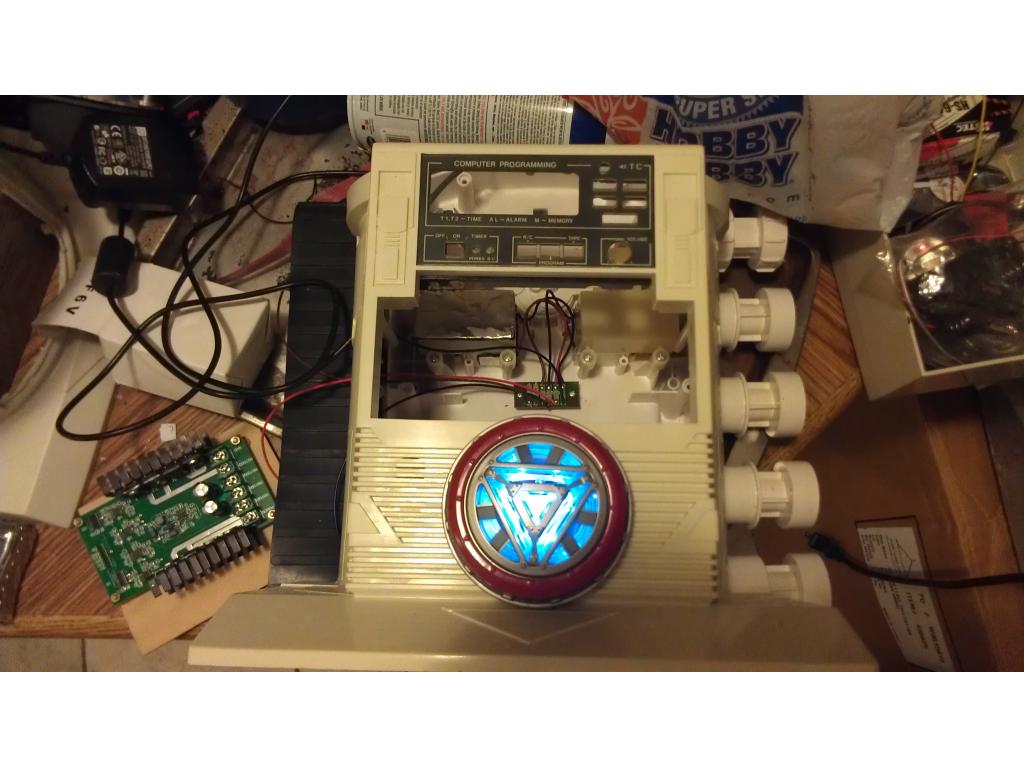
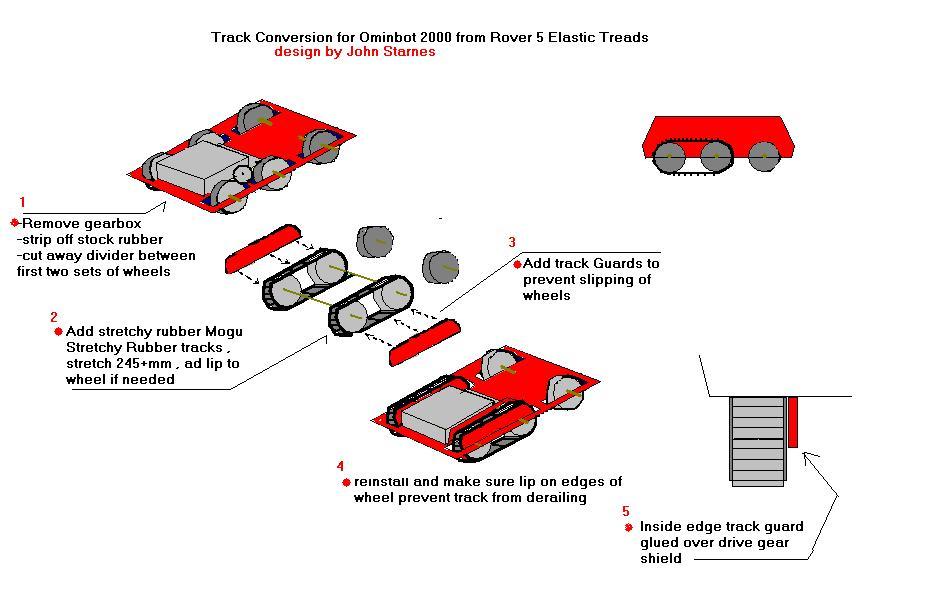
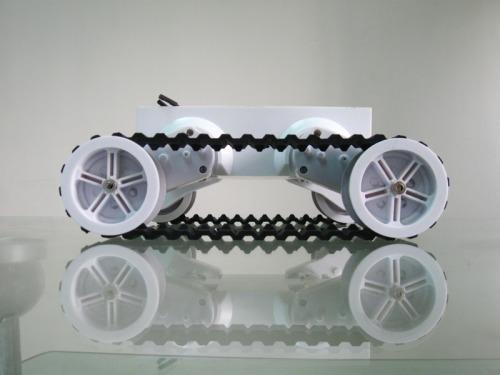
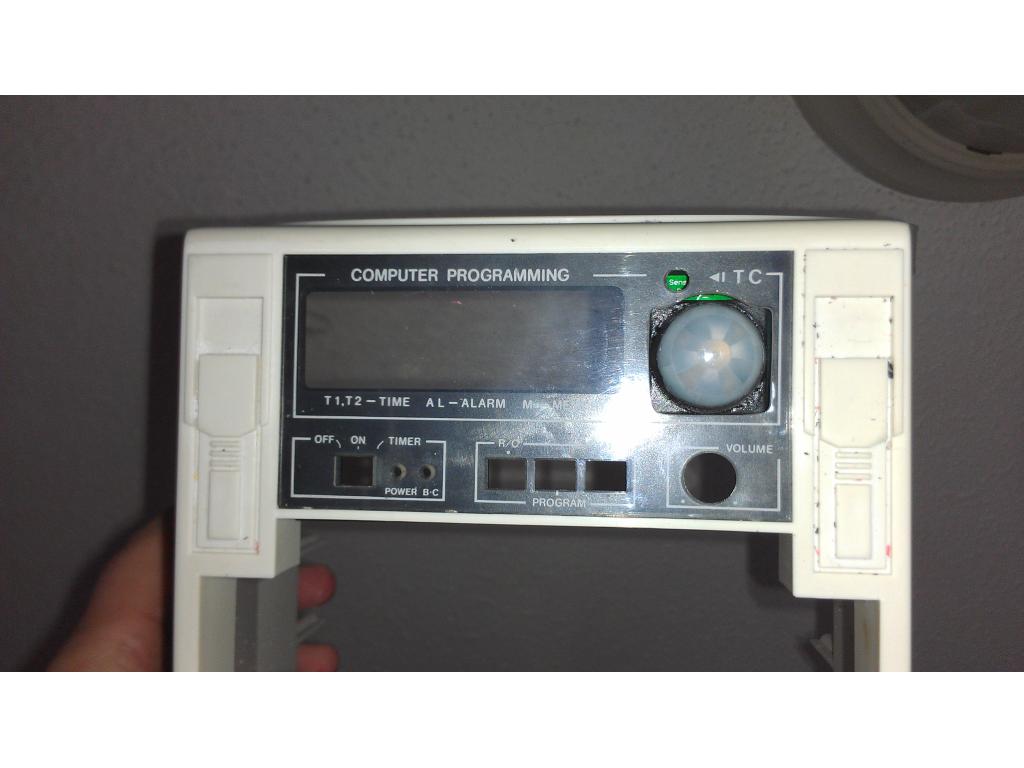
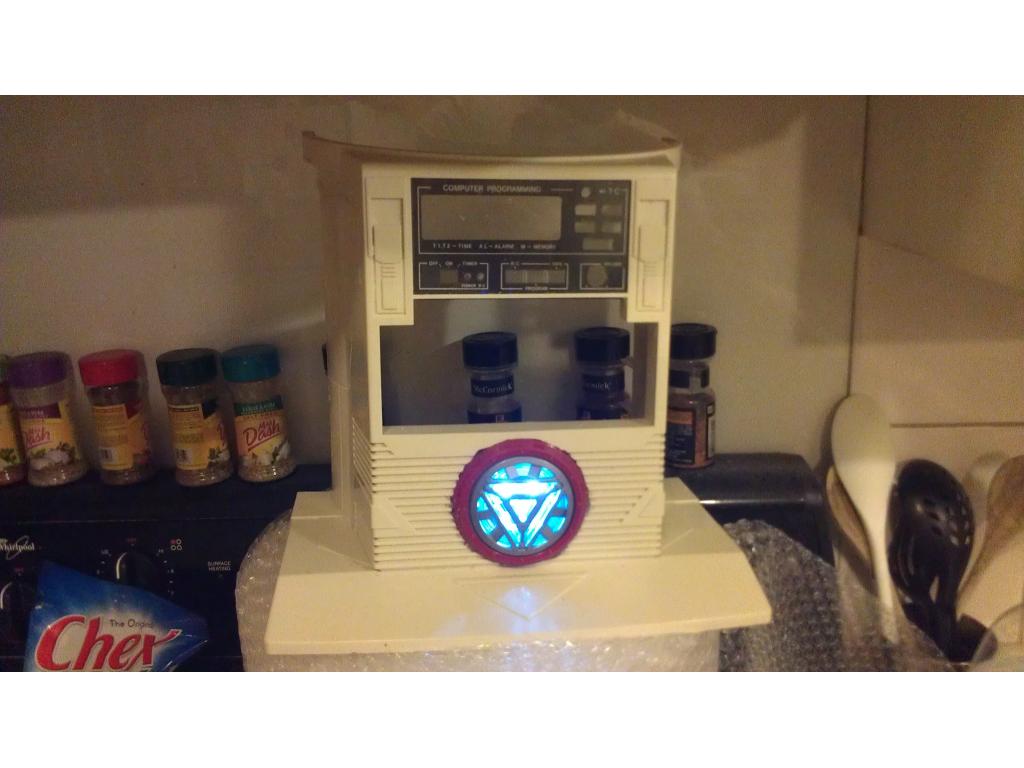
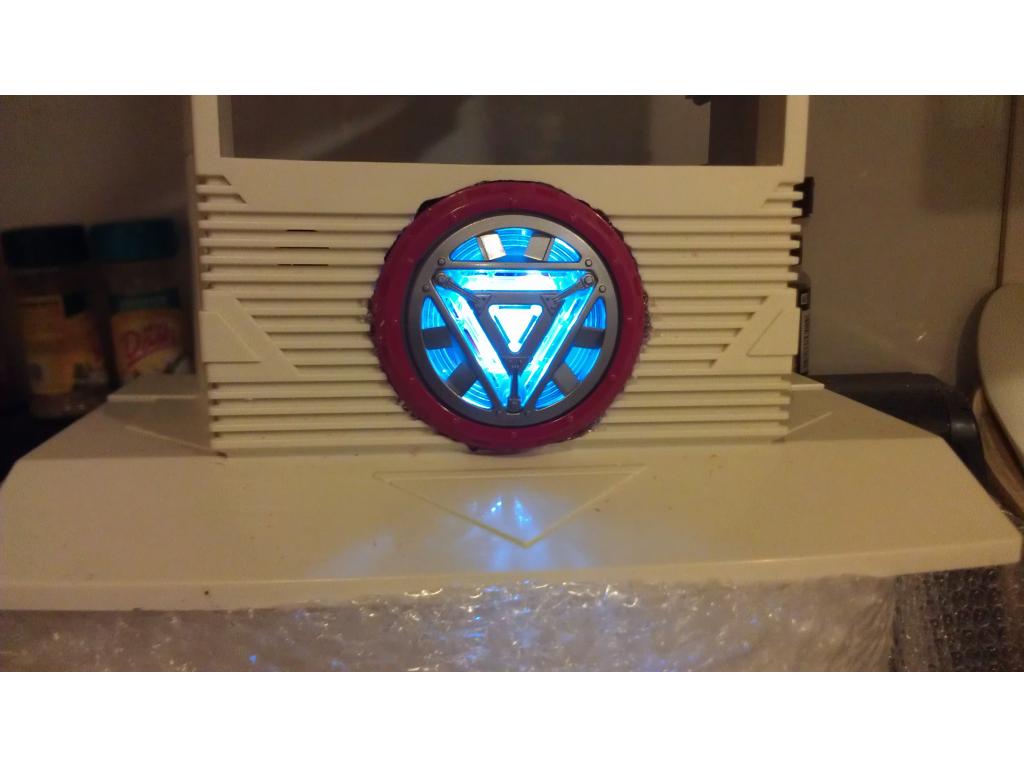
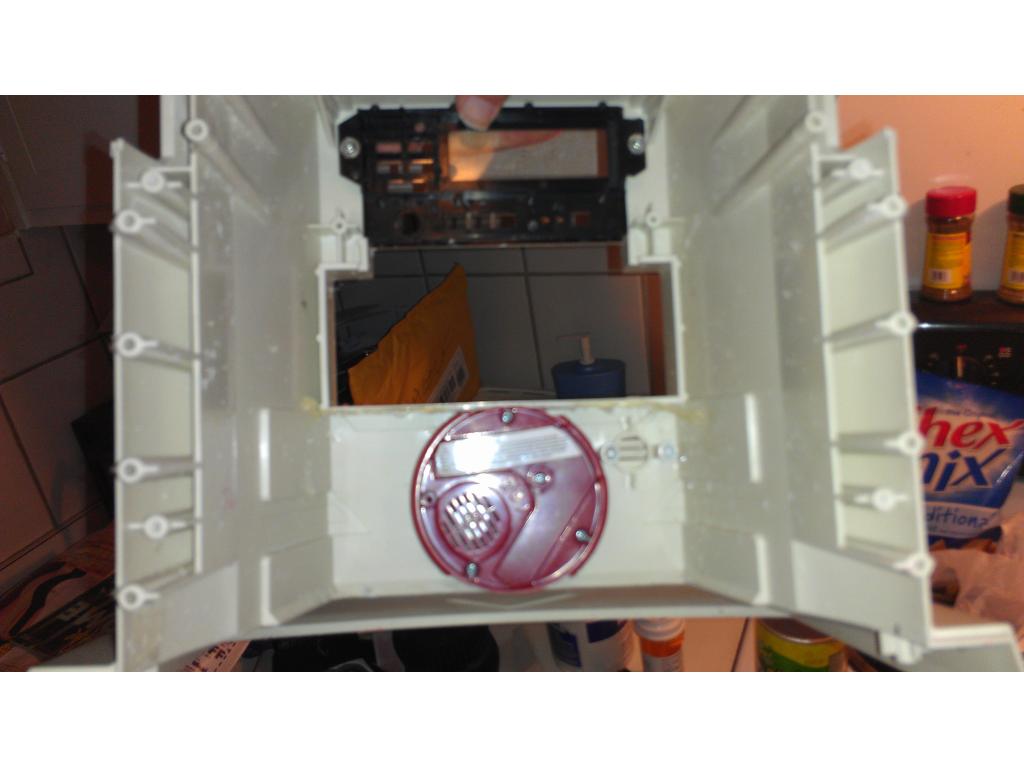
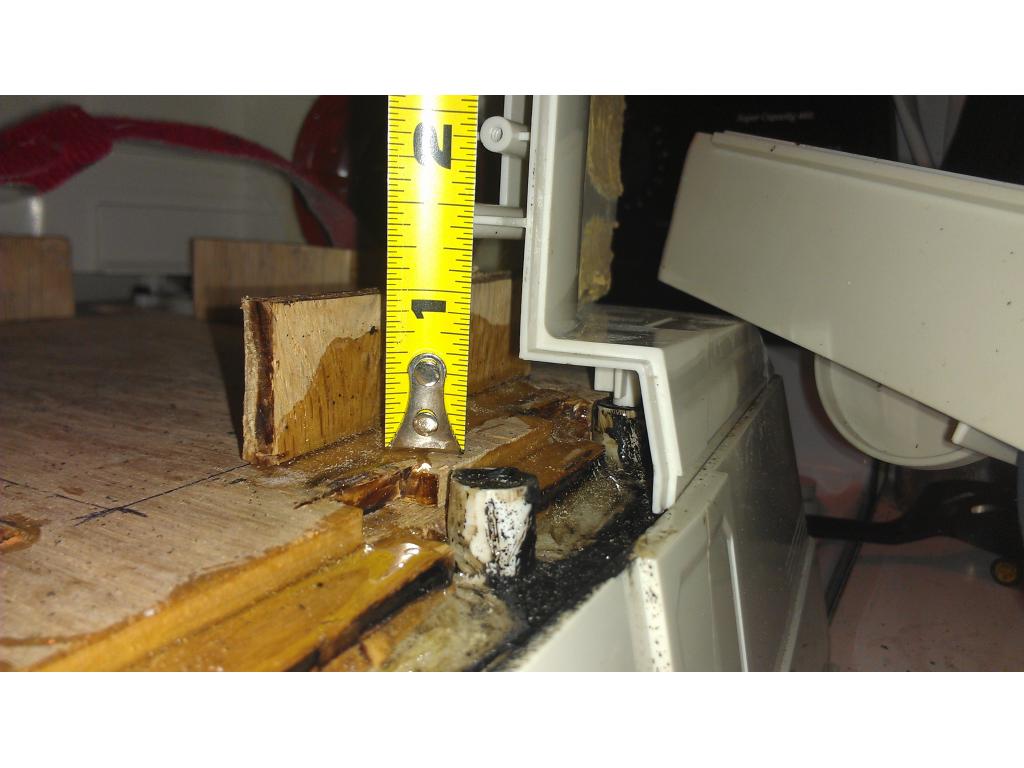
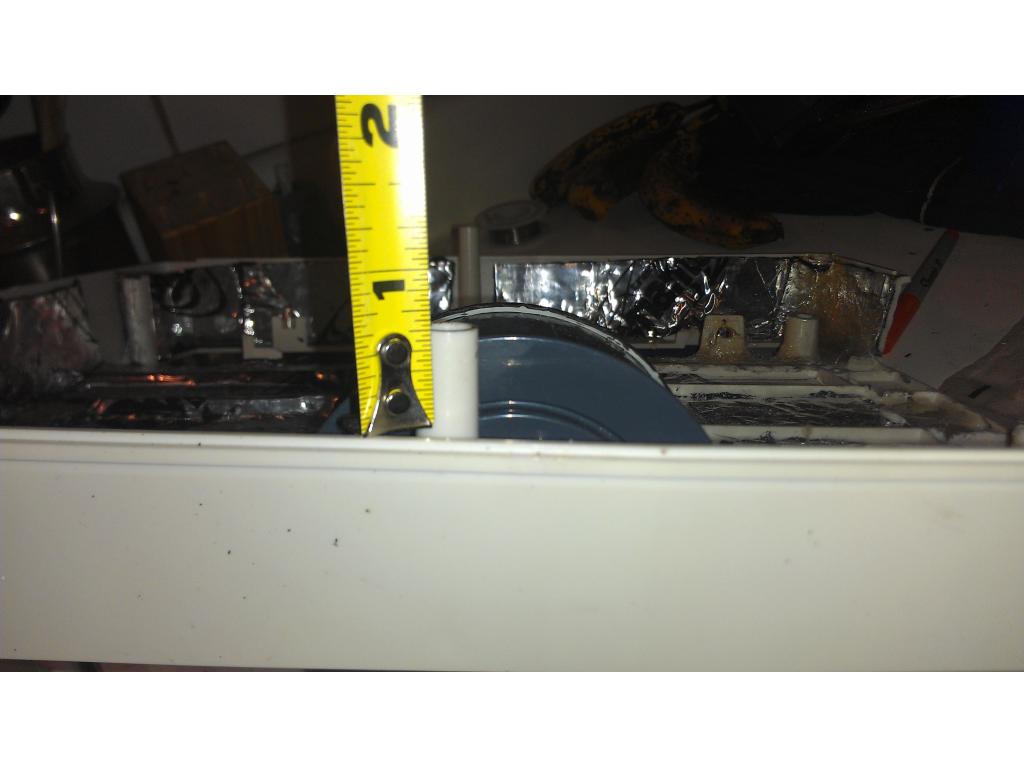
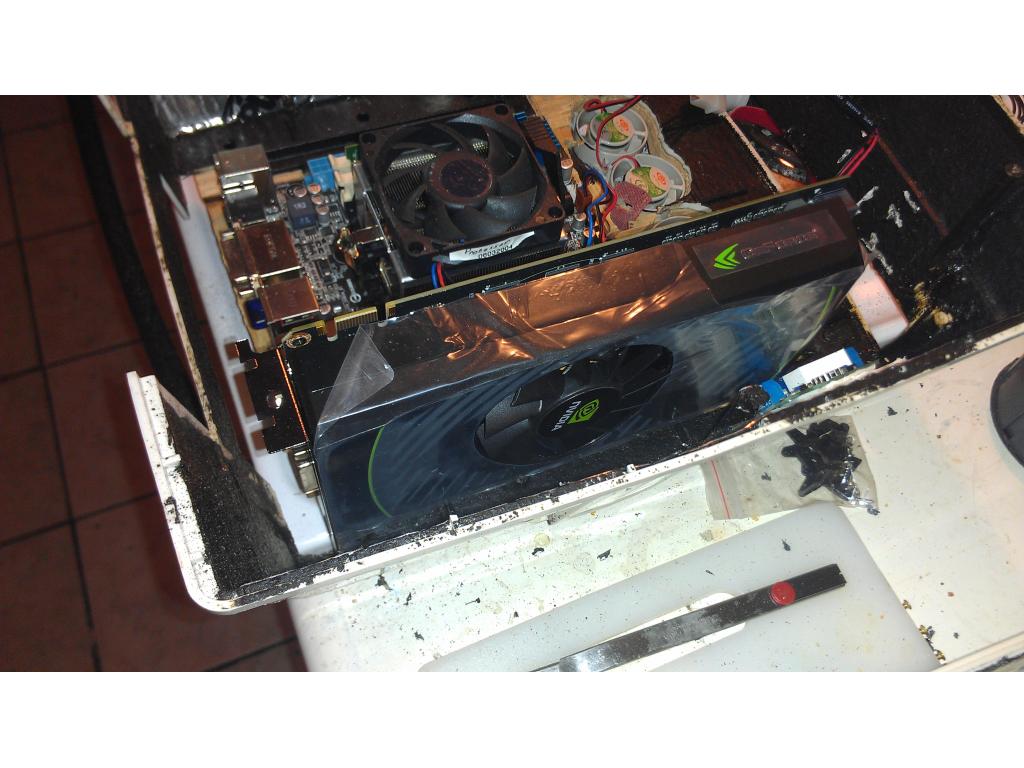
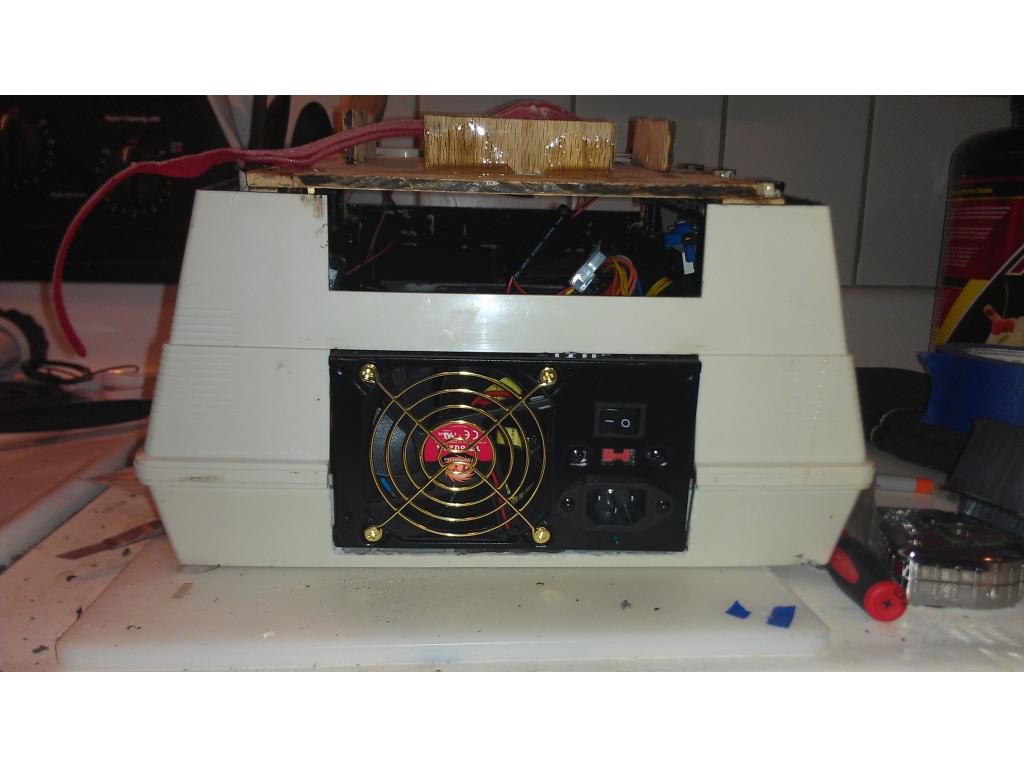
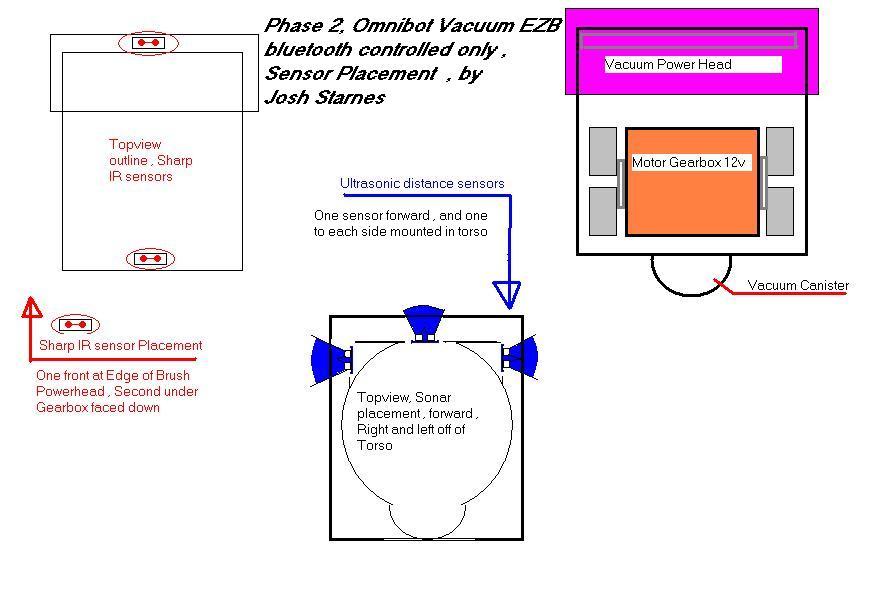
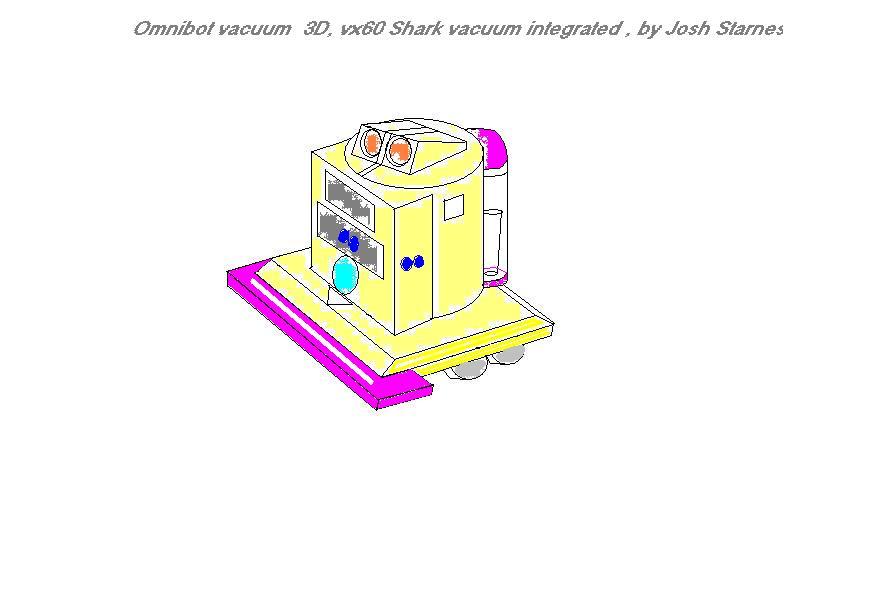
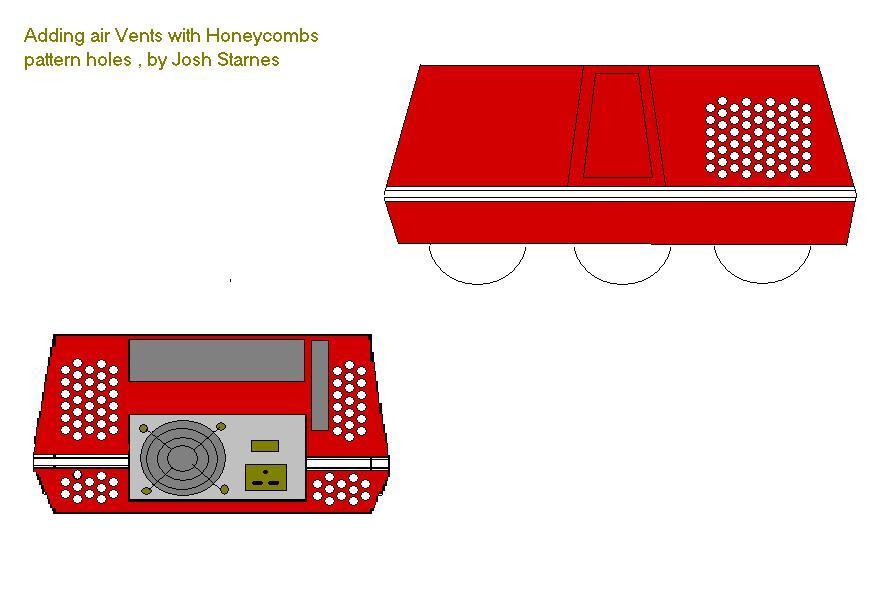
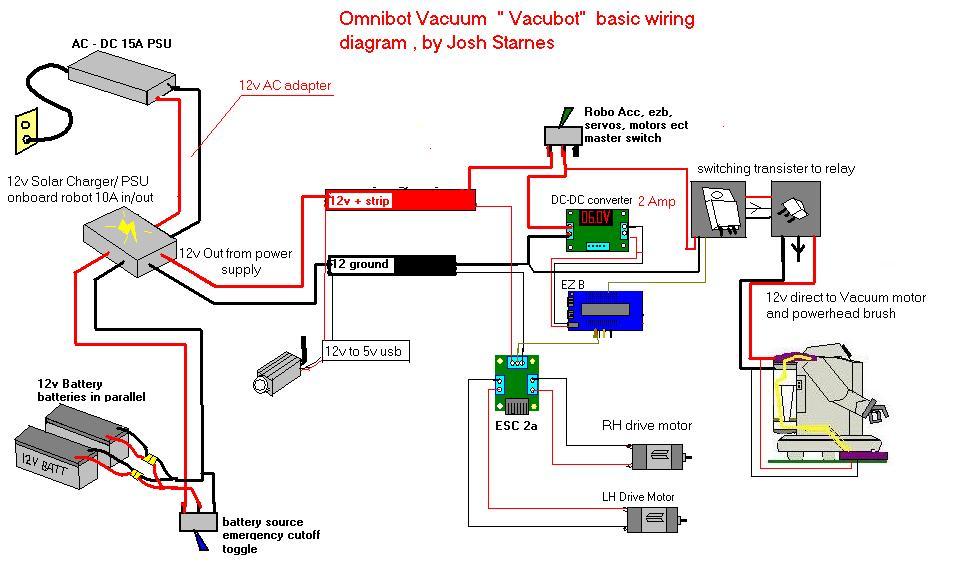
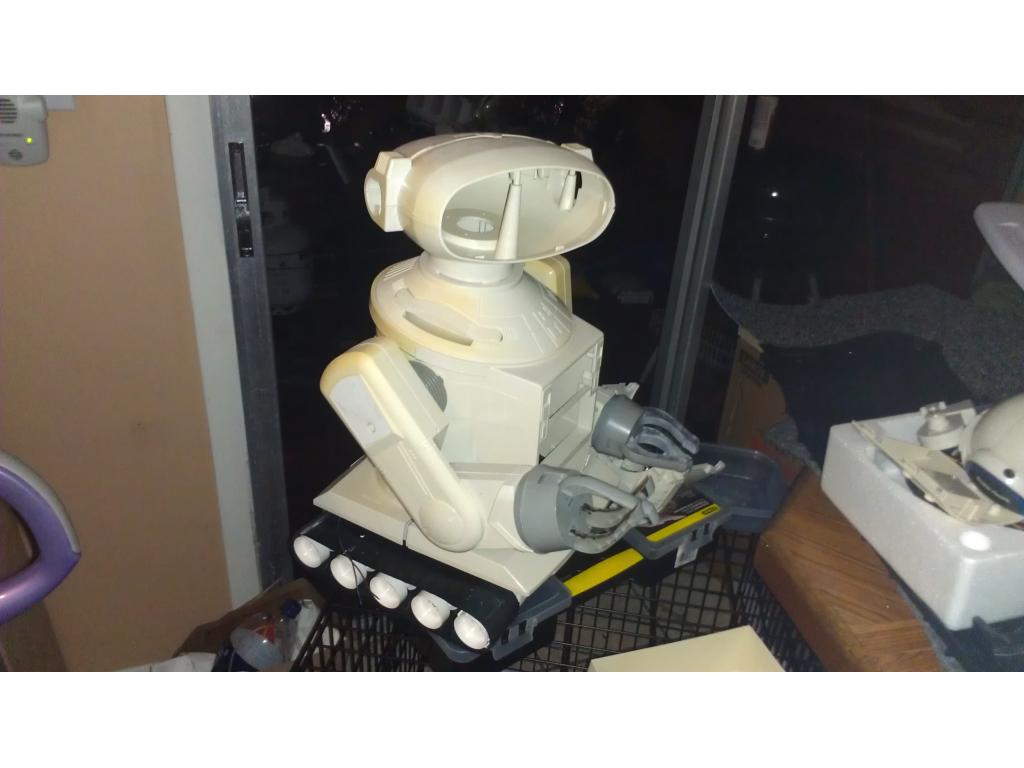
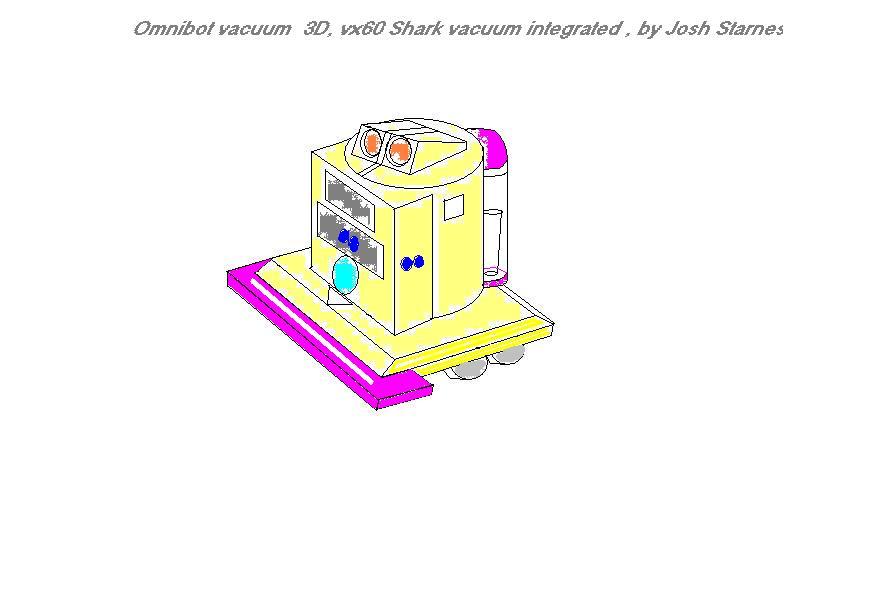
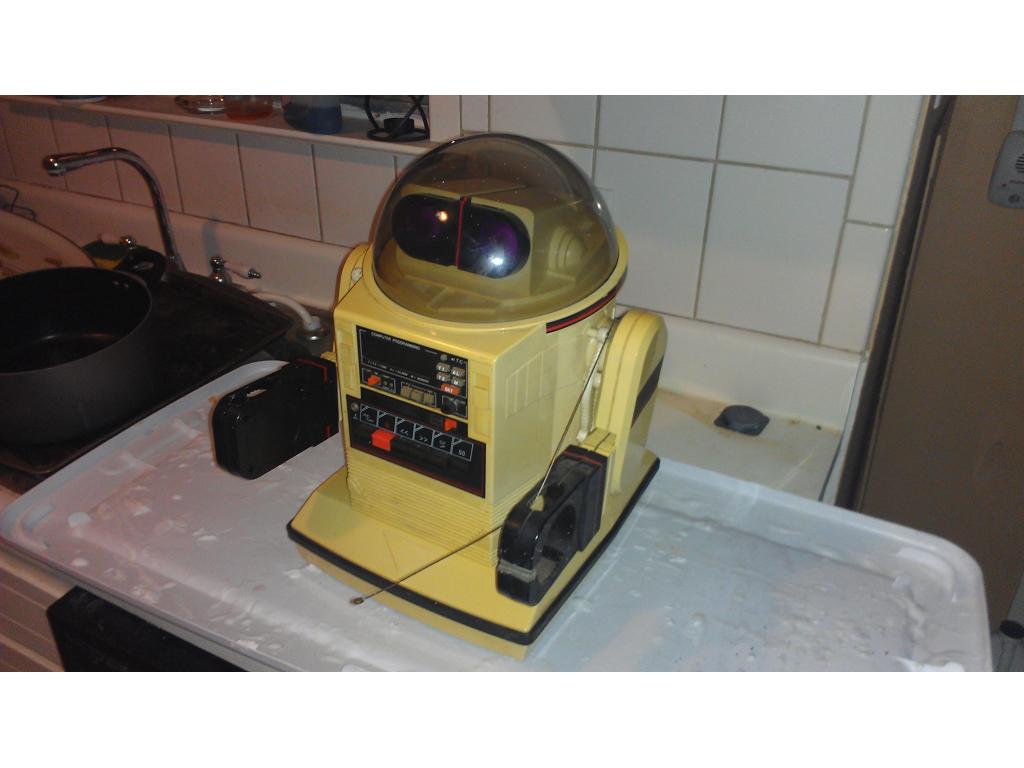
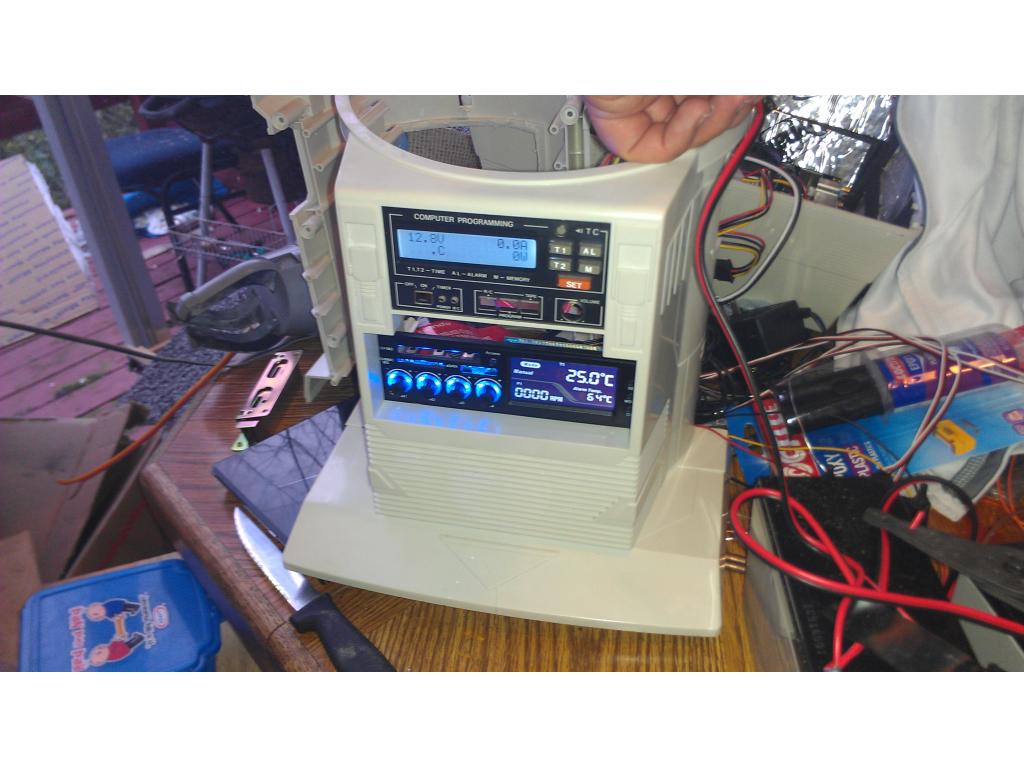
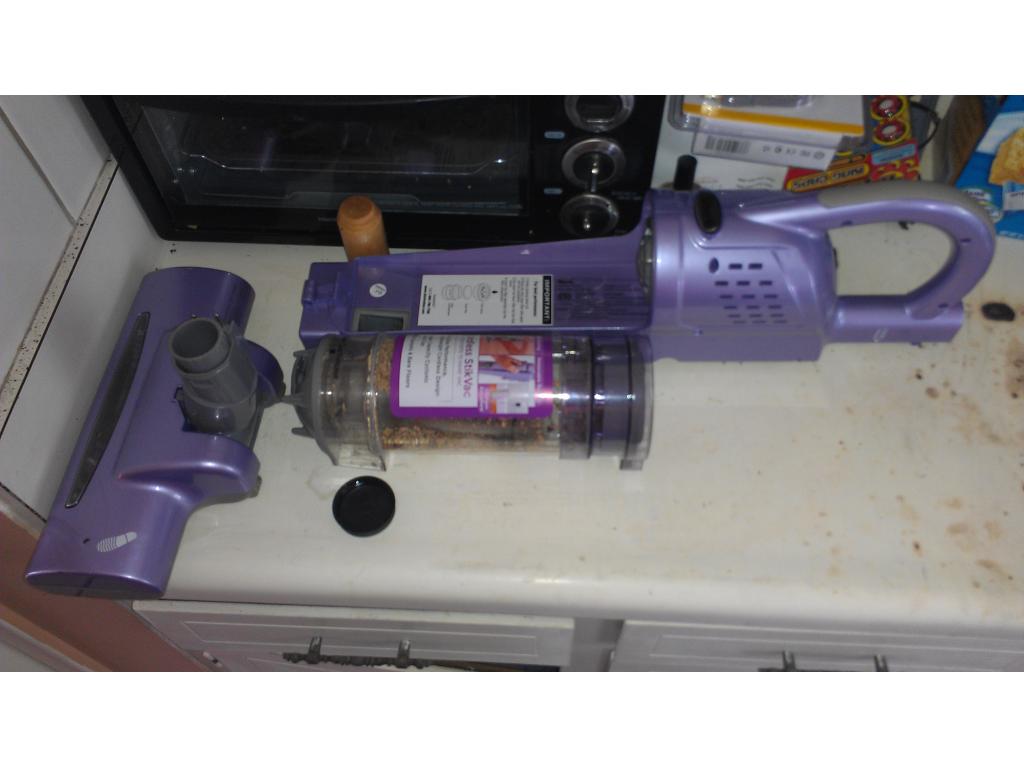
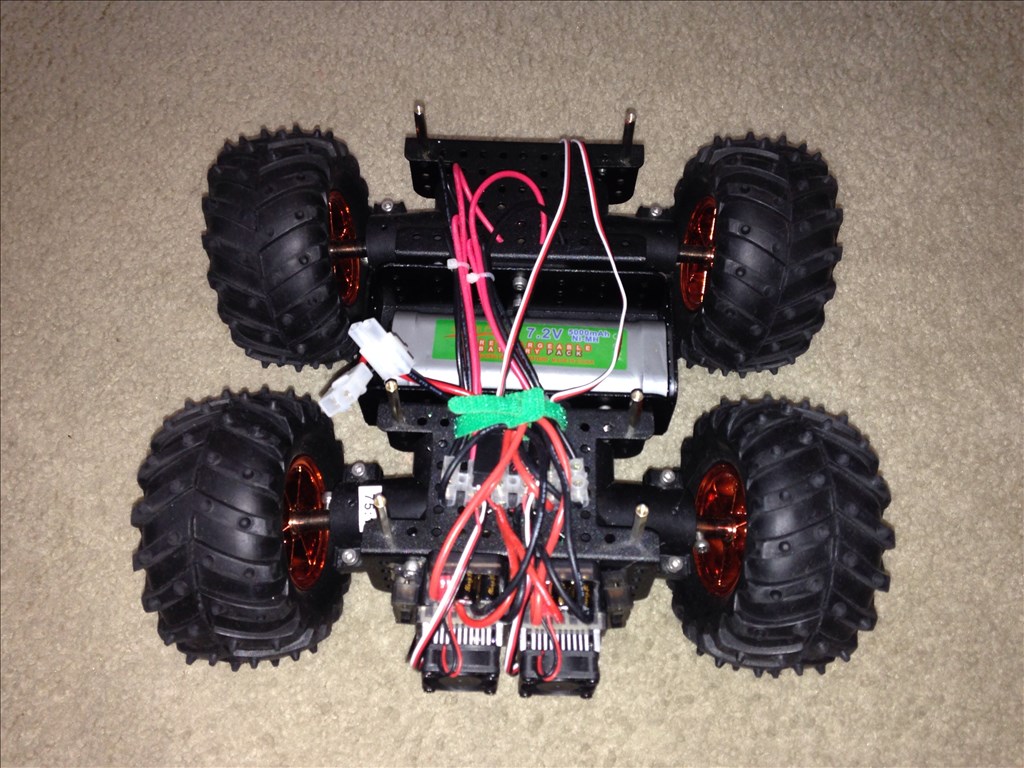
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.
By jstarne1
— Last update
Discover more robots
Tmesserschmidt's Simone AI (Openfembot)
Synthiam ARC makes coding Simone easy: openFembot humanoid AI featured on Servo Magazine with open-source hardware,...
Fisha's Wall-E Wall-E From Poland - Tribute To My Newborn...
DIY Wall-E robot with 12-14 servos, camera, ultrasonic sensor, MP3 trigger, amplifier, laser diode, VU meter mouth and...
Jdvann's My Dog
Dog (Droid On Guard): low-cost Dagu 4WD DIY robot to ward off boredom and help stave off Alzheimer's by keeping the mind...

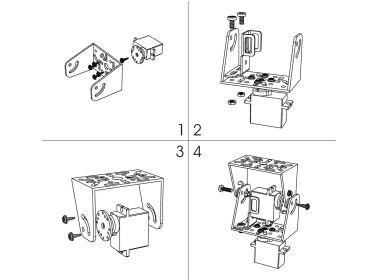
Fantastic Josh! I may have to steal that for my big bot.
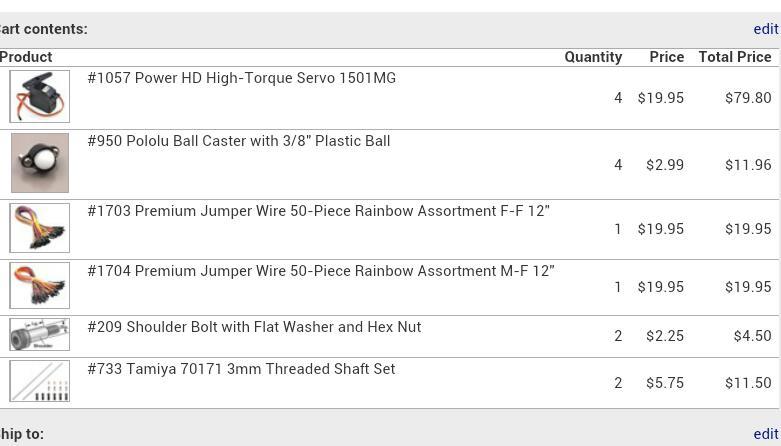
dam again JOSH beat me to it,i bought the servo,s already to do the same thing
@brett thanks man trying to do "original" things , I know everything had already been done but I can give it my own spin. And sir when am I gonna see your robo running around , with that controller he should be climbing the walls.
@robotmaker yup I gotta stay ahead of the game!
I'm am building in a safety work that my ex gf would use when she wanted me to leave her alone "BANNANAS" !
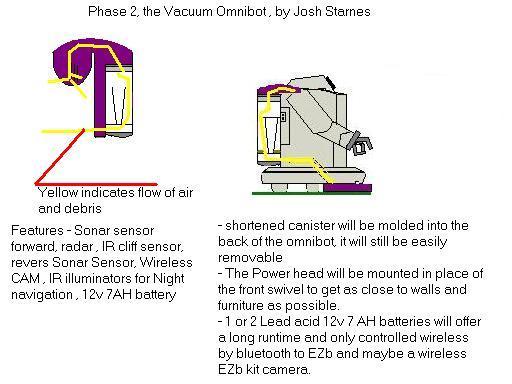
Now I just need to trim the neck , extend torso , put vacuum in and that's about it...
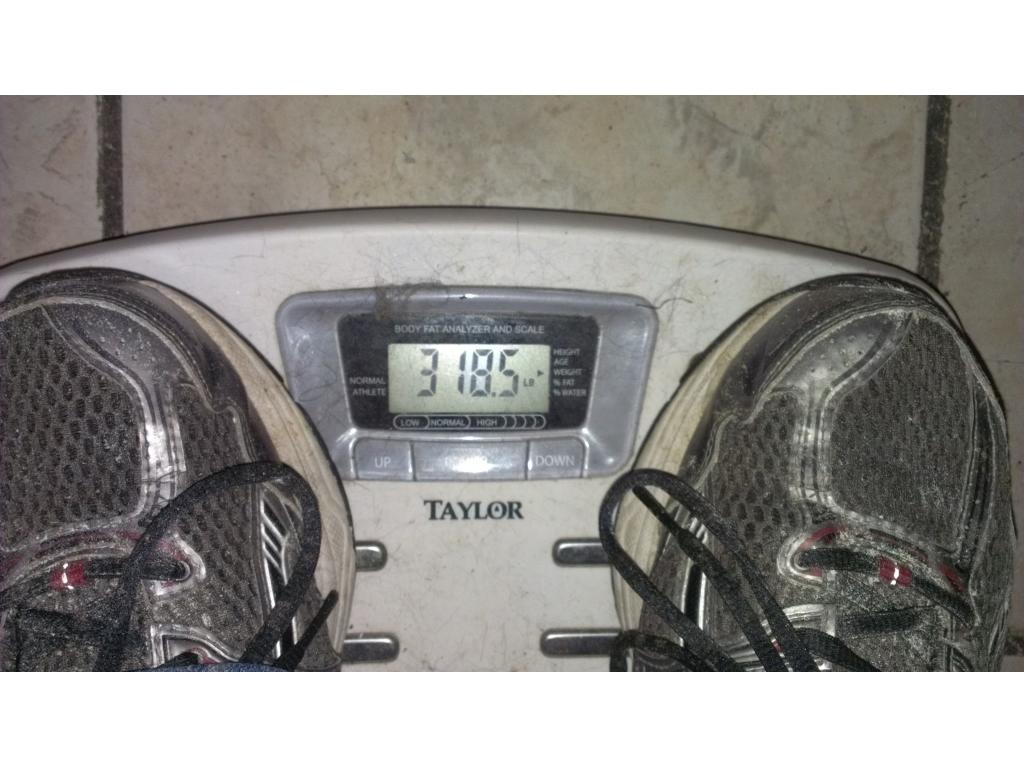
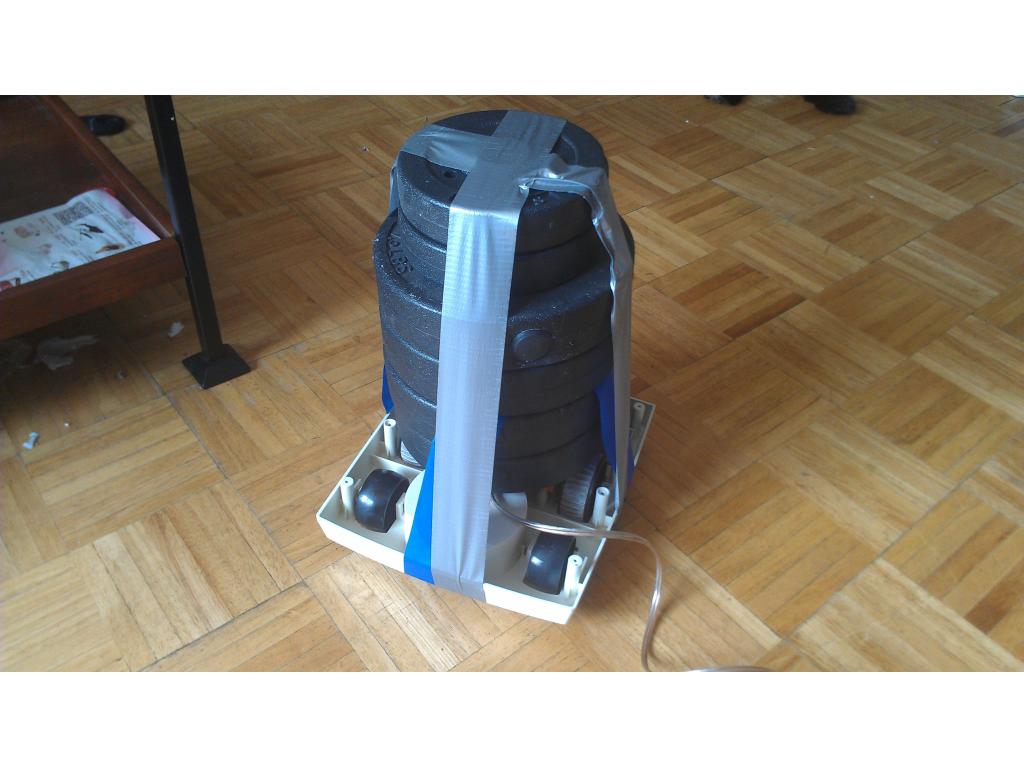
pretty soon the robot will weigh so much ,be hard to pick it up and move it
Yeah hopefully he stays in working condition so he can move himself...
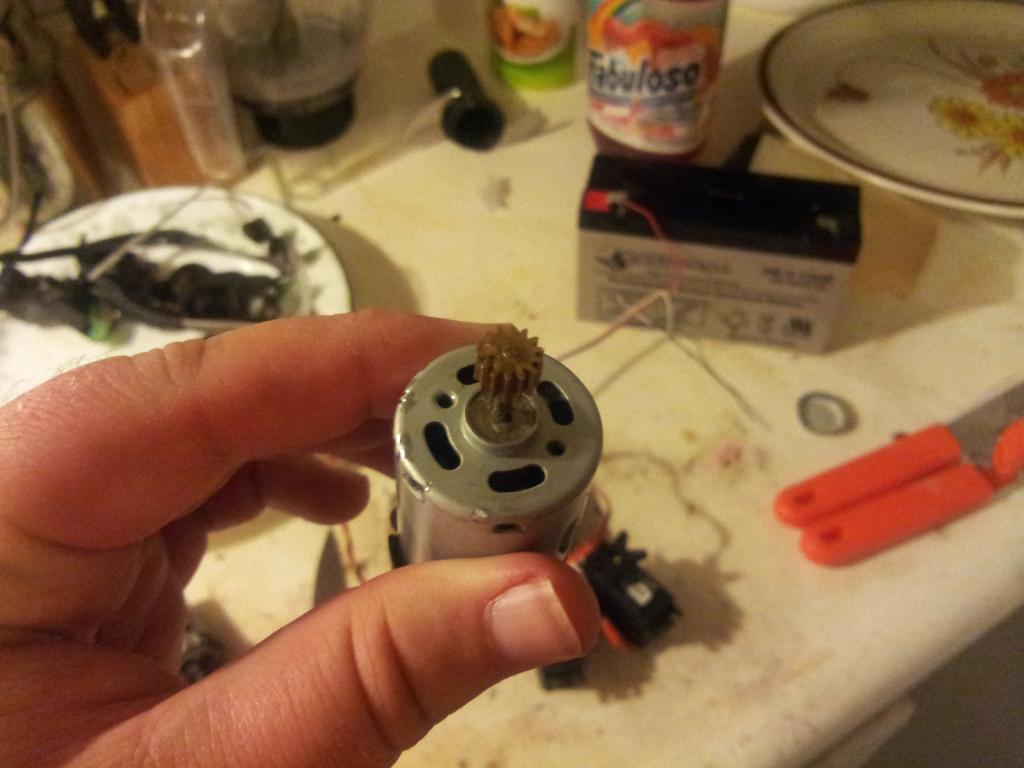
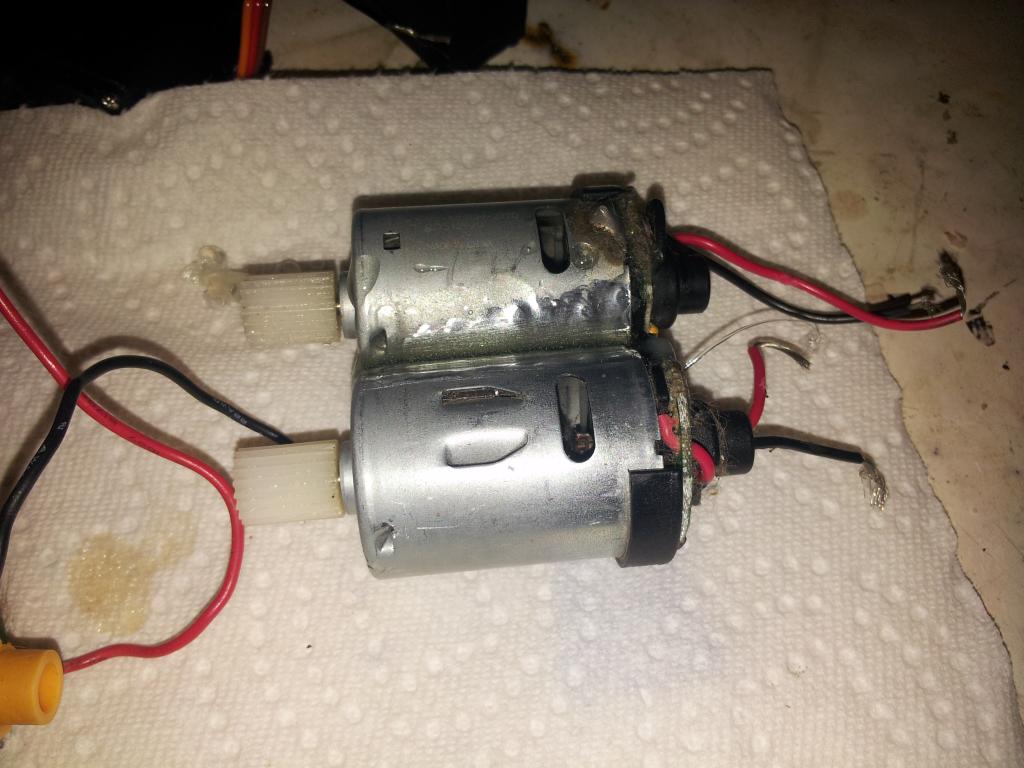
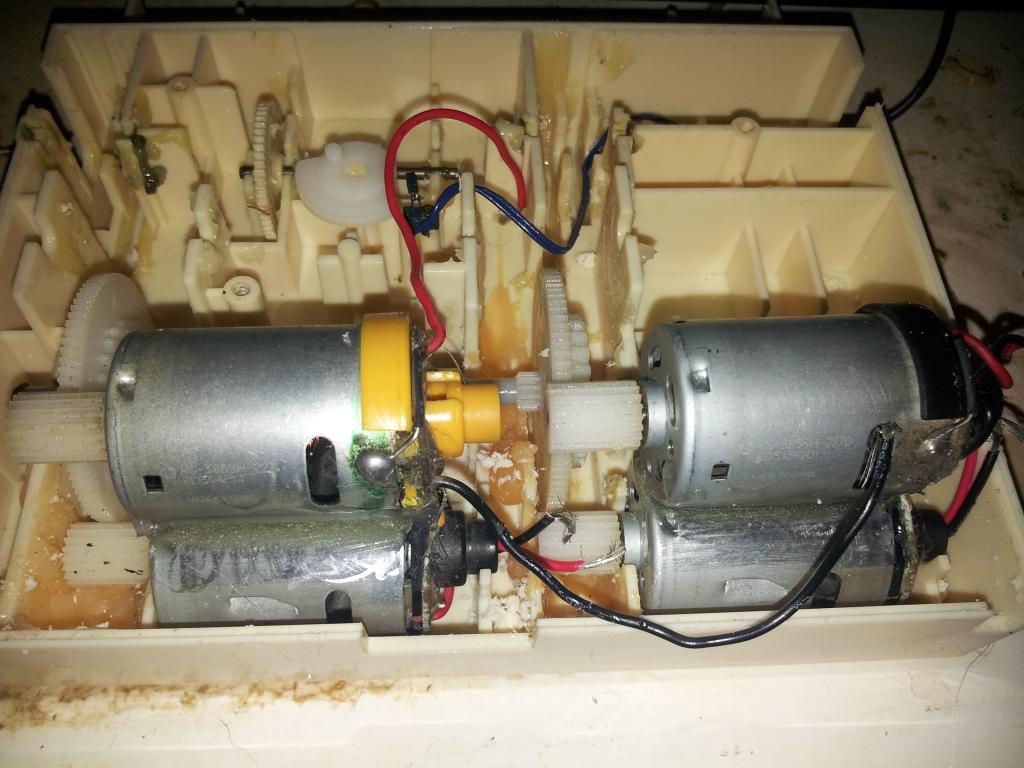
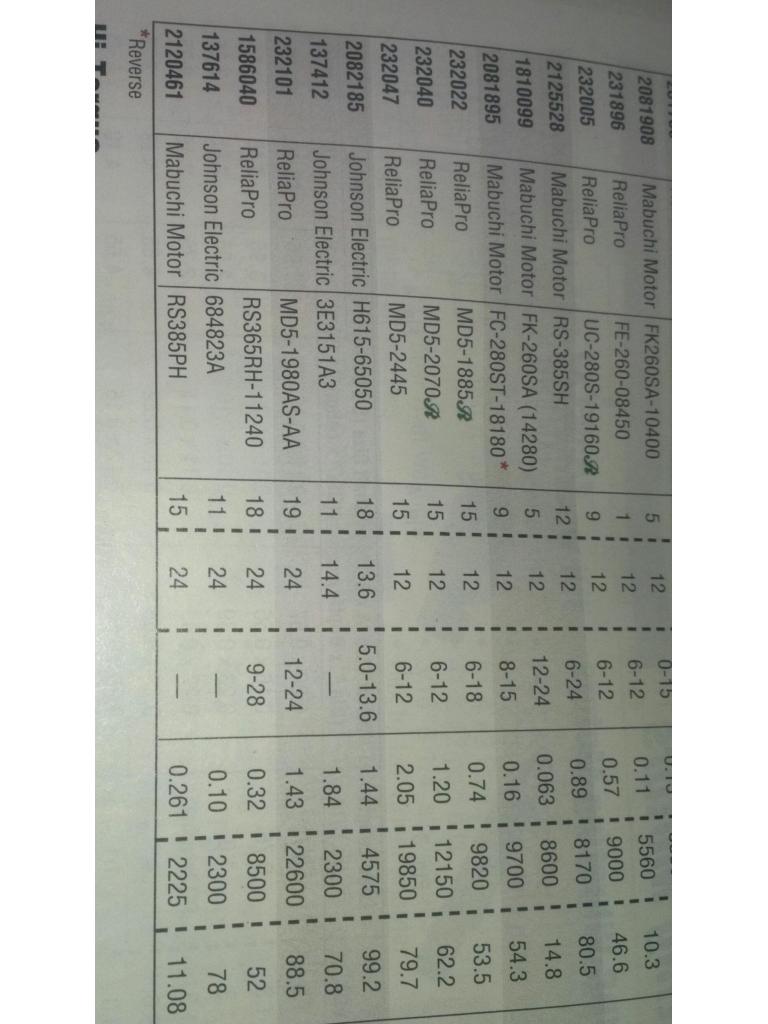
You guys think my bots too fat? I was thinking of upgrading to those Johnson motors that has.90g cm torque maybe they would have a little more power.
We're more talking about your back... hahahhaha
did you get your packake i sent you JOSH