
cE9s4PsOgeBQIORwjd5!~~60_1-634818020230156250.jpg)



Lupuc4g~~60_35-634706297915000000.jpg)


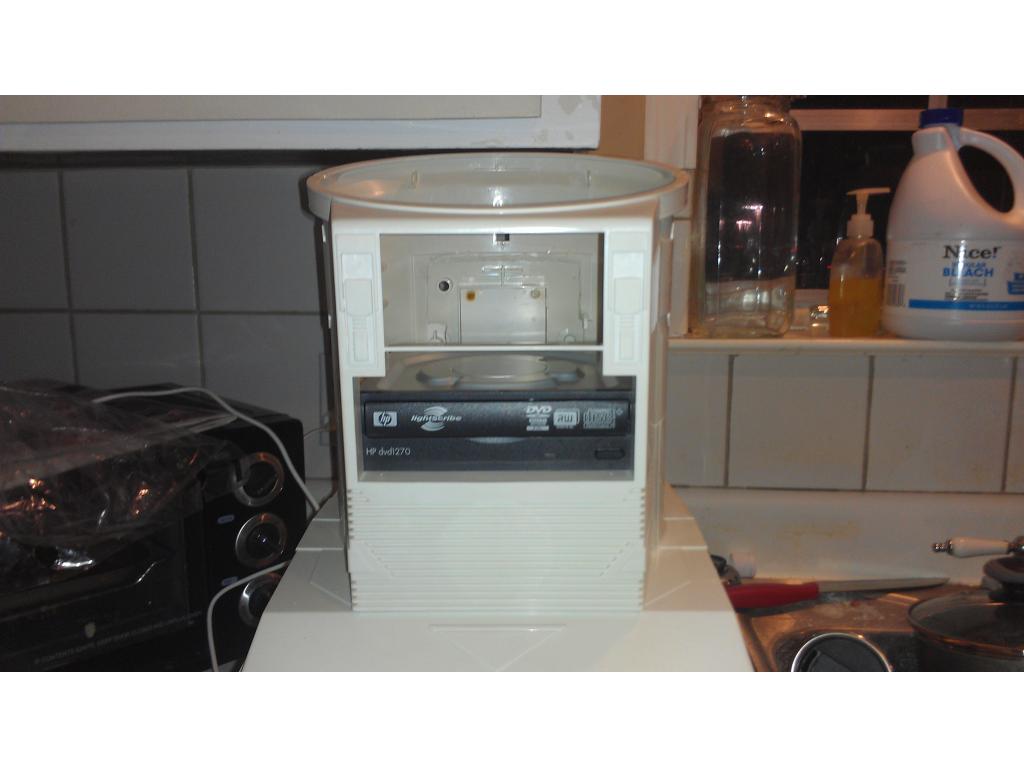
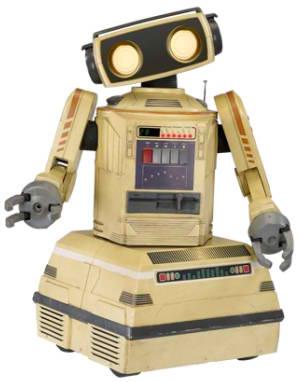
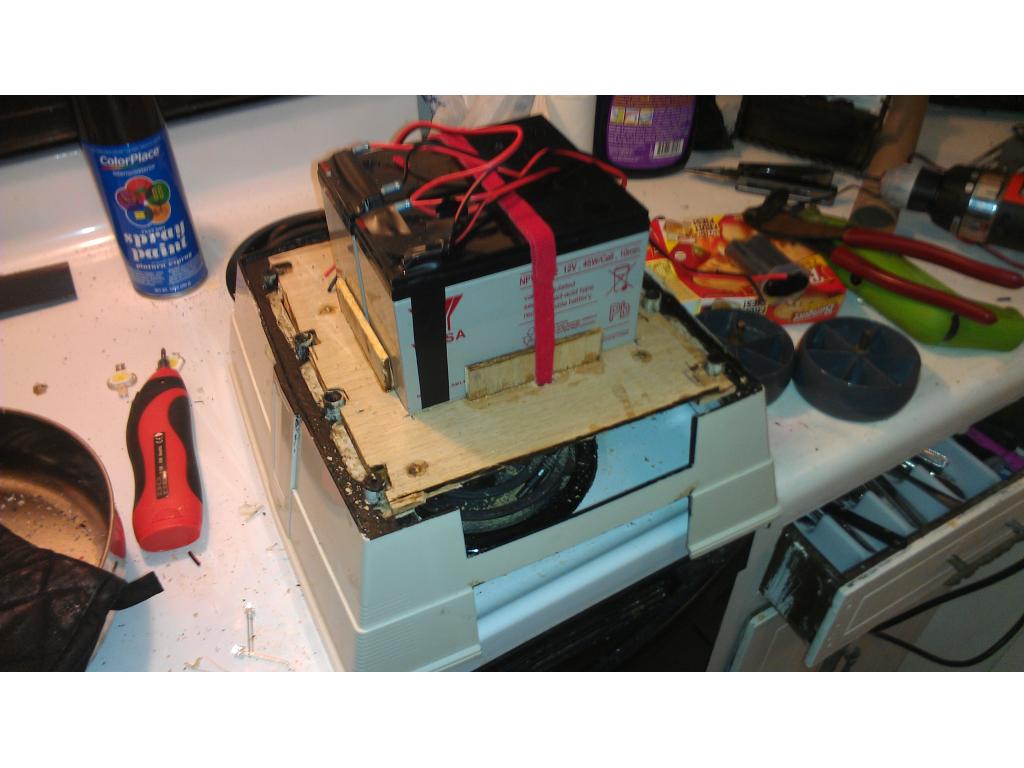

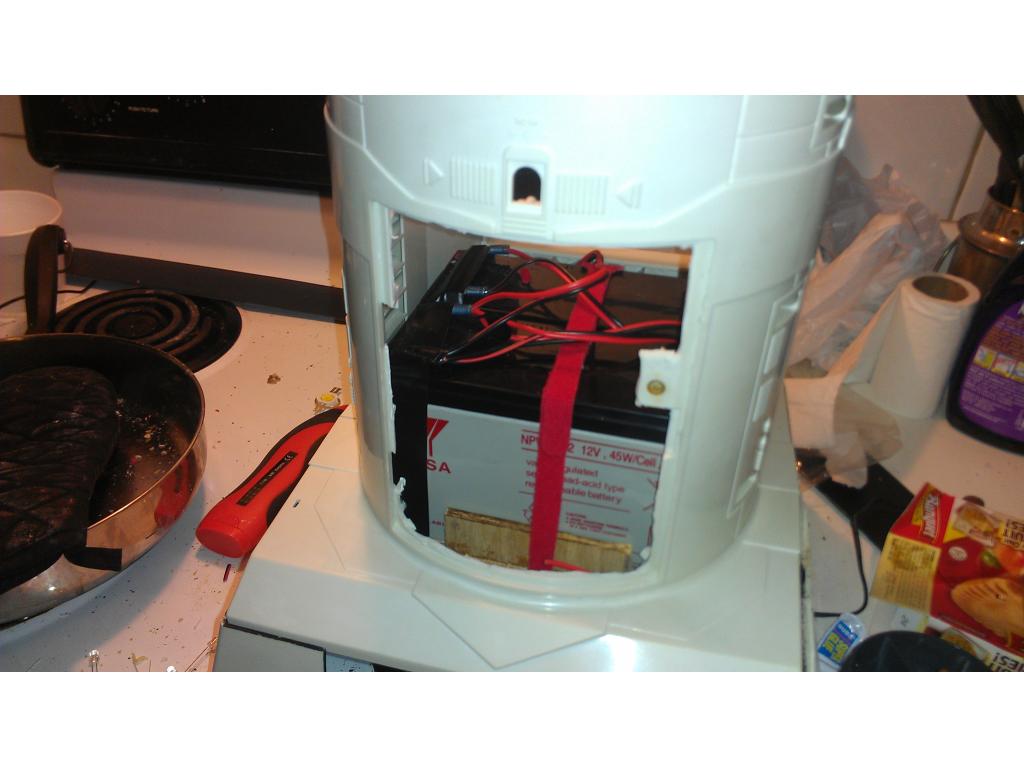
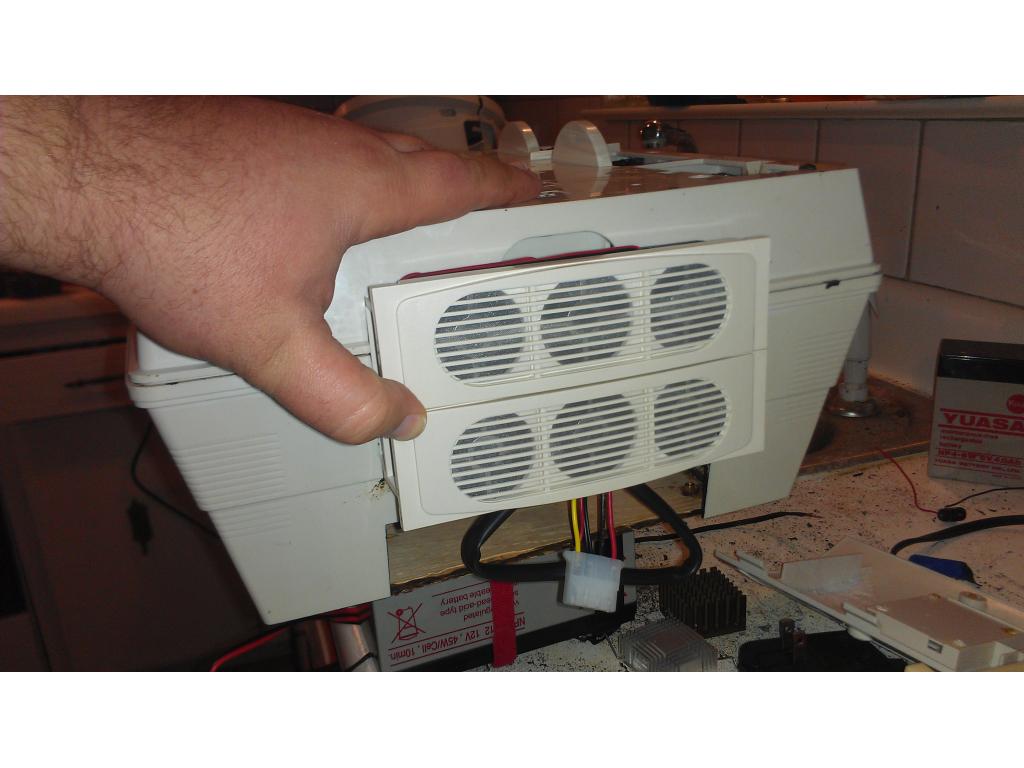
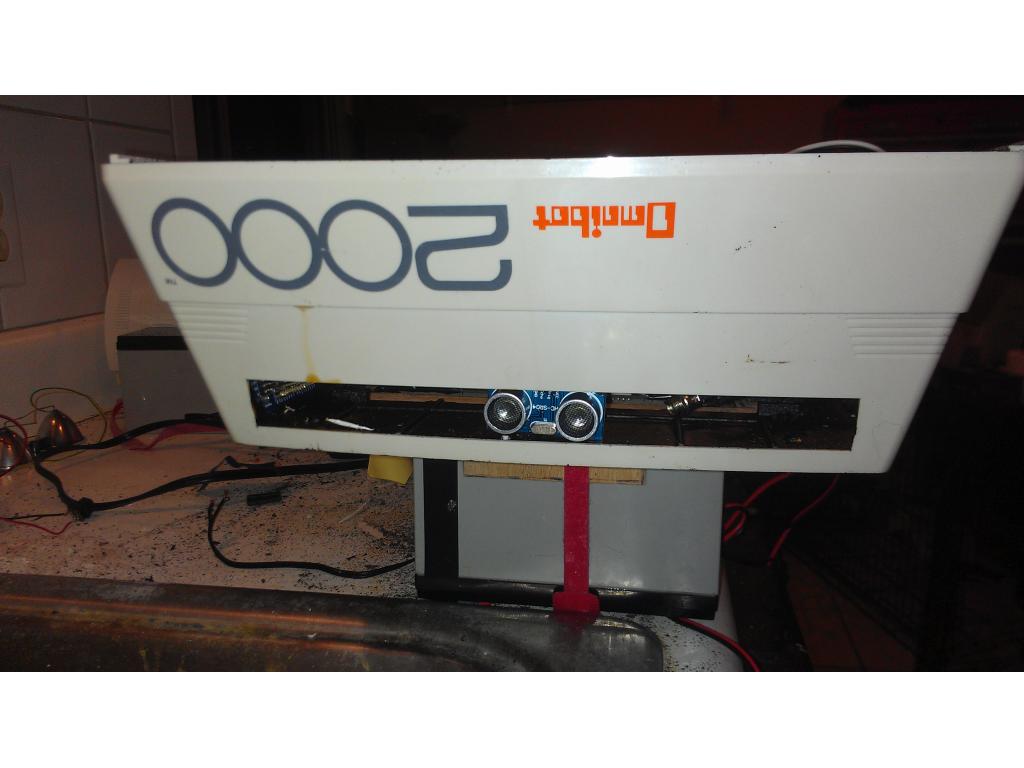
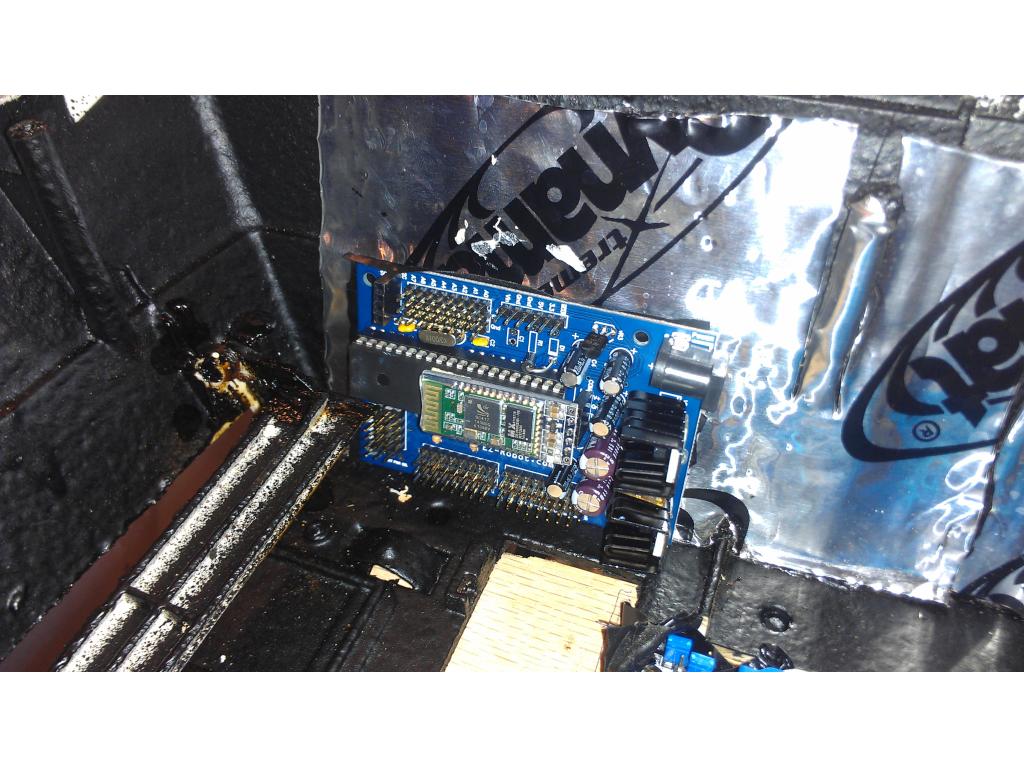
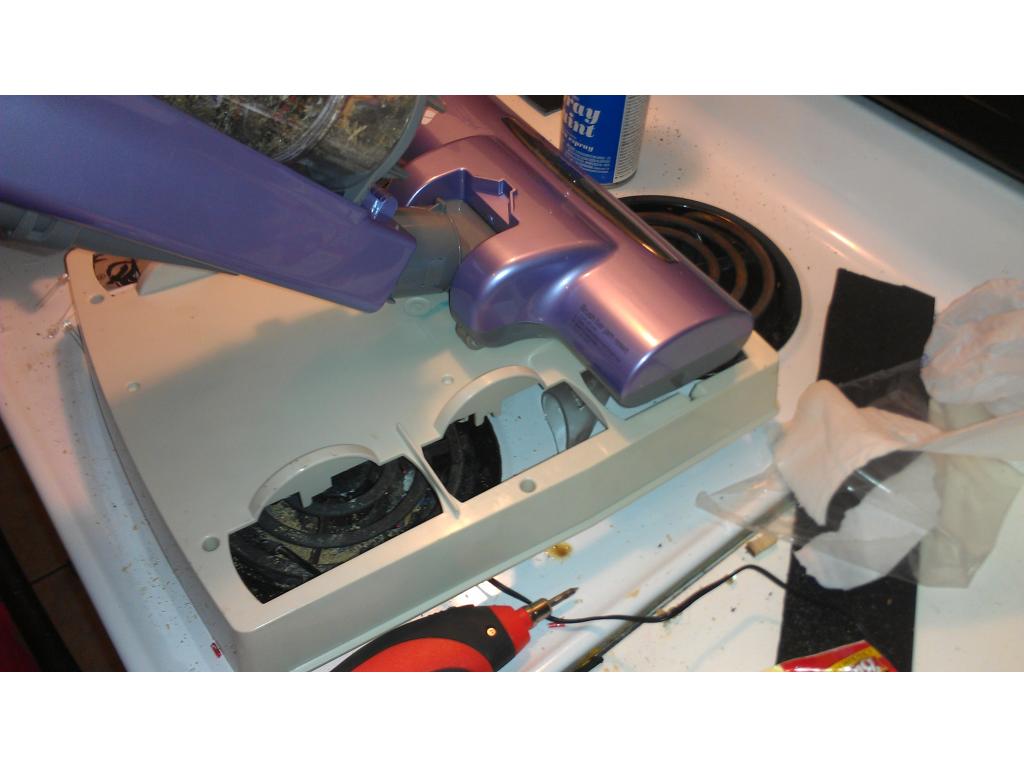

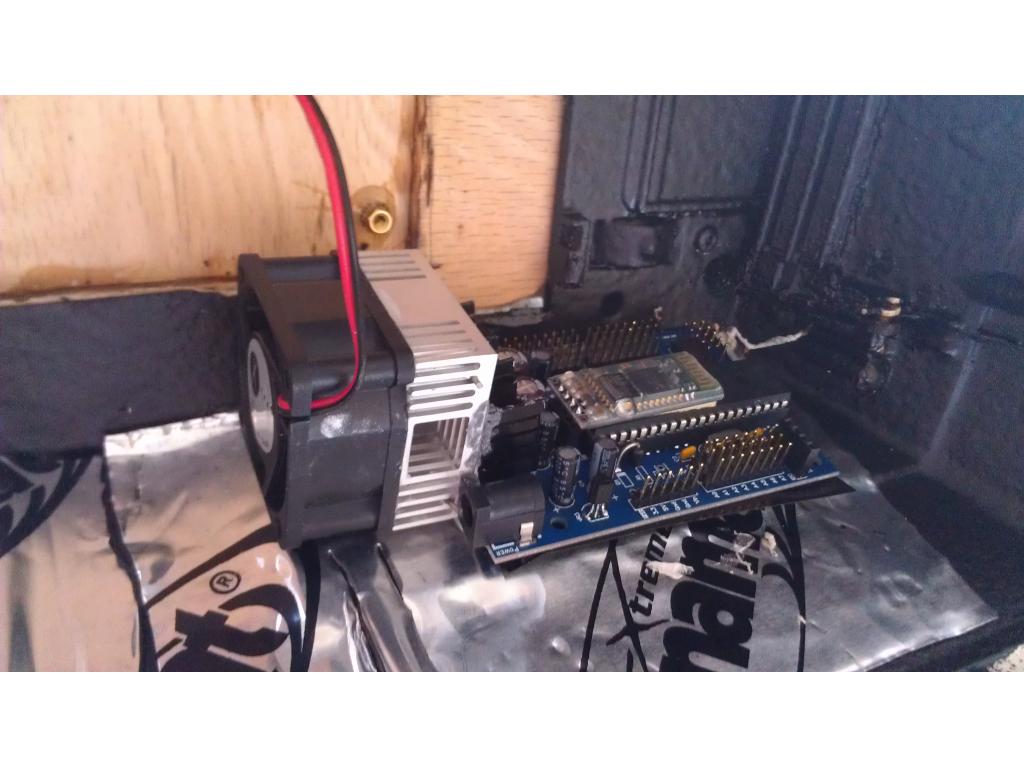
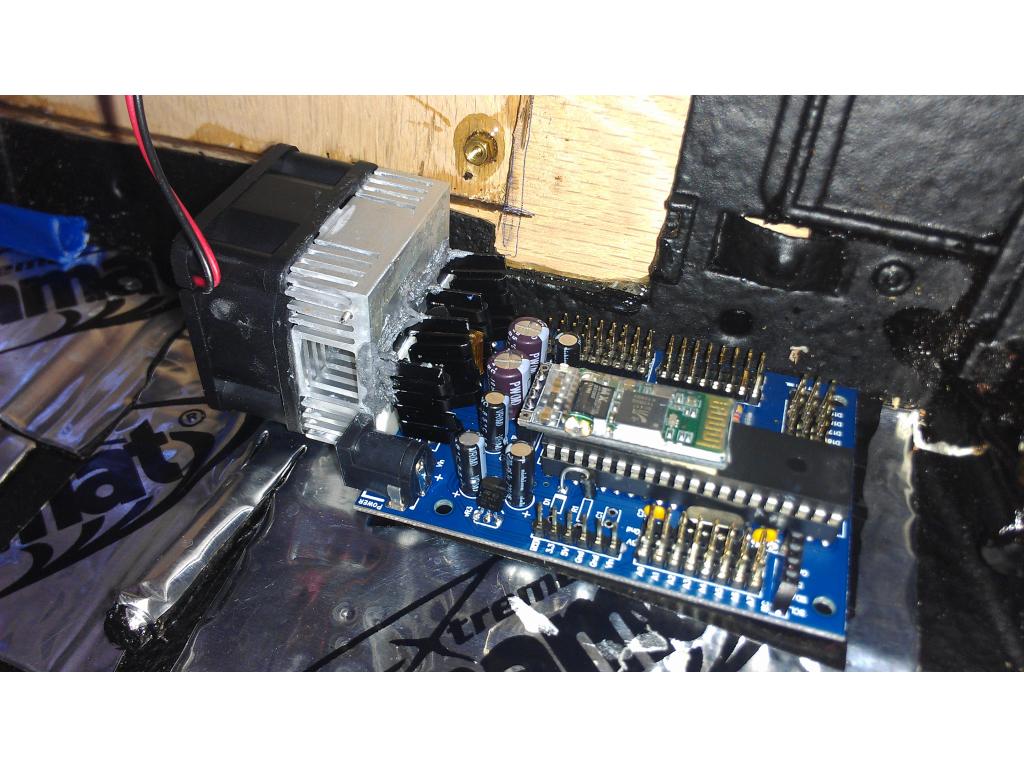
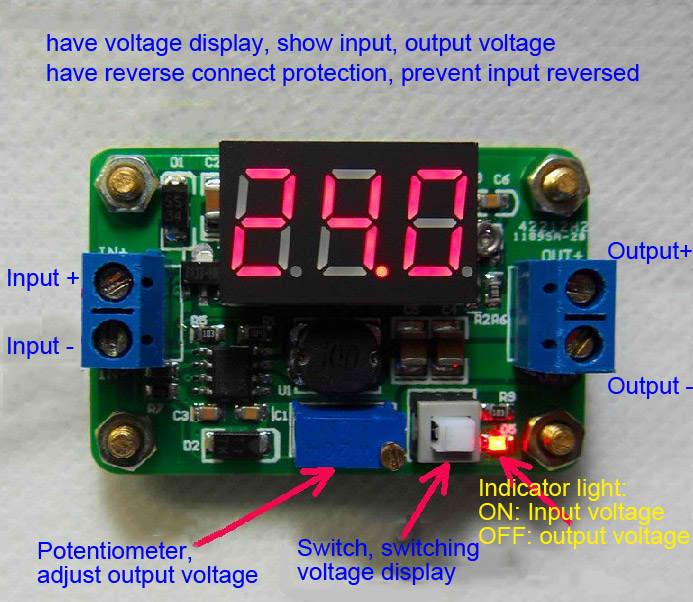

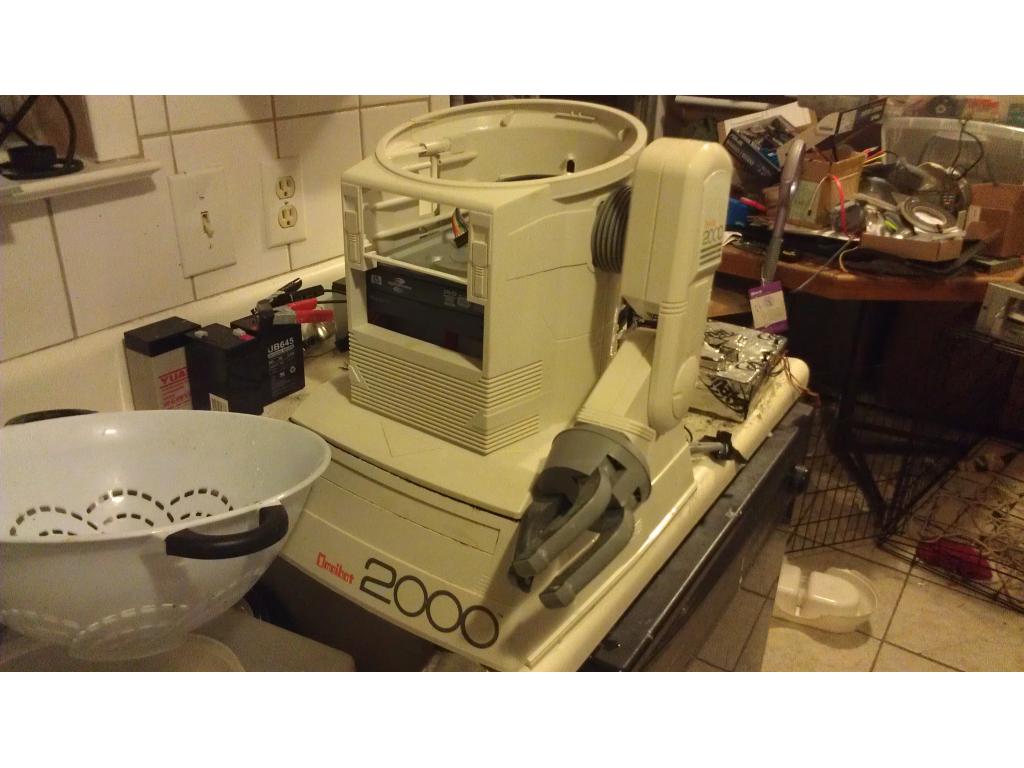
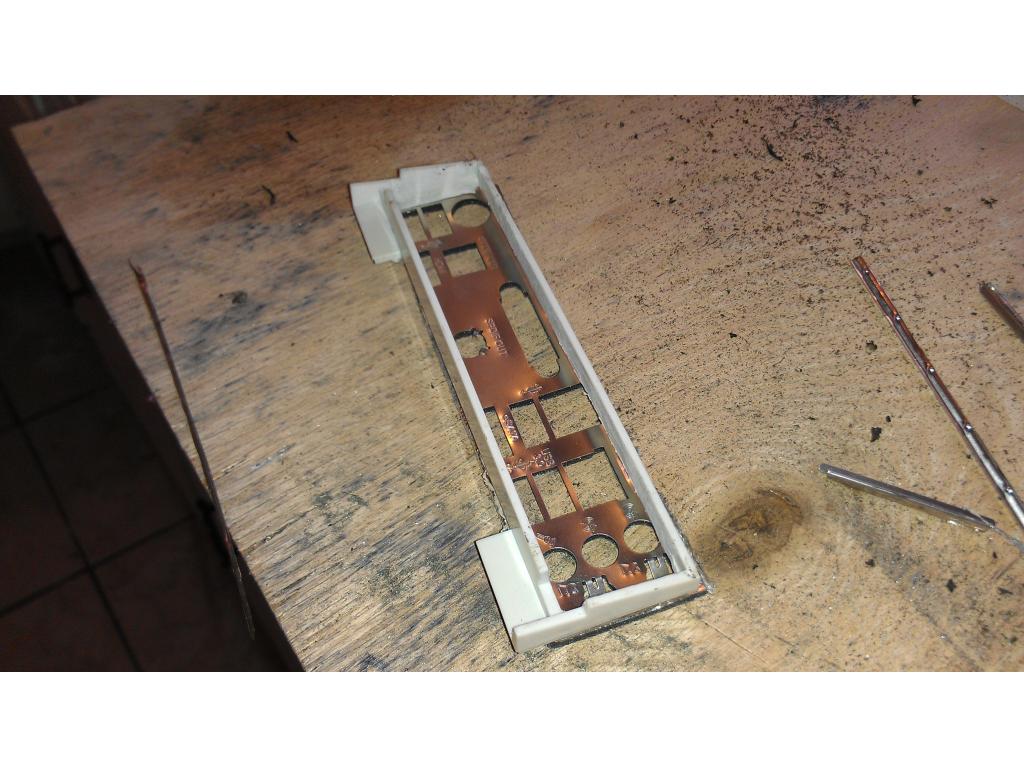
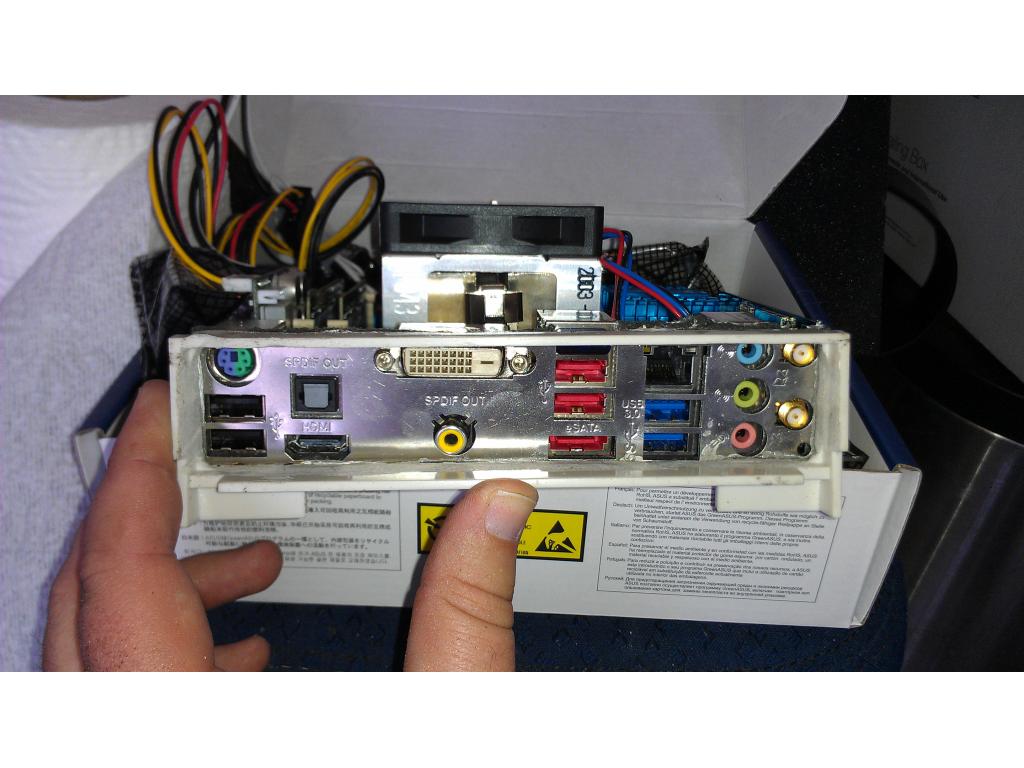
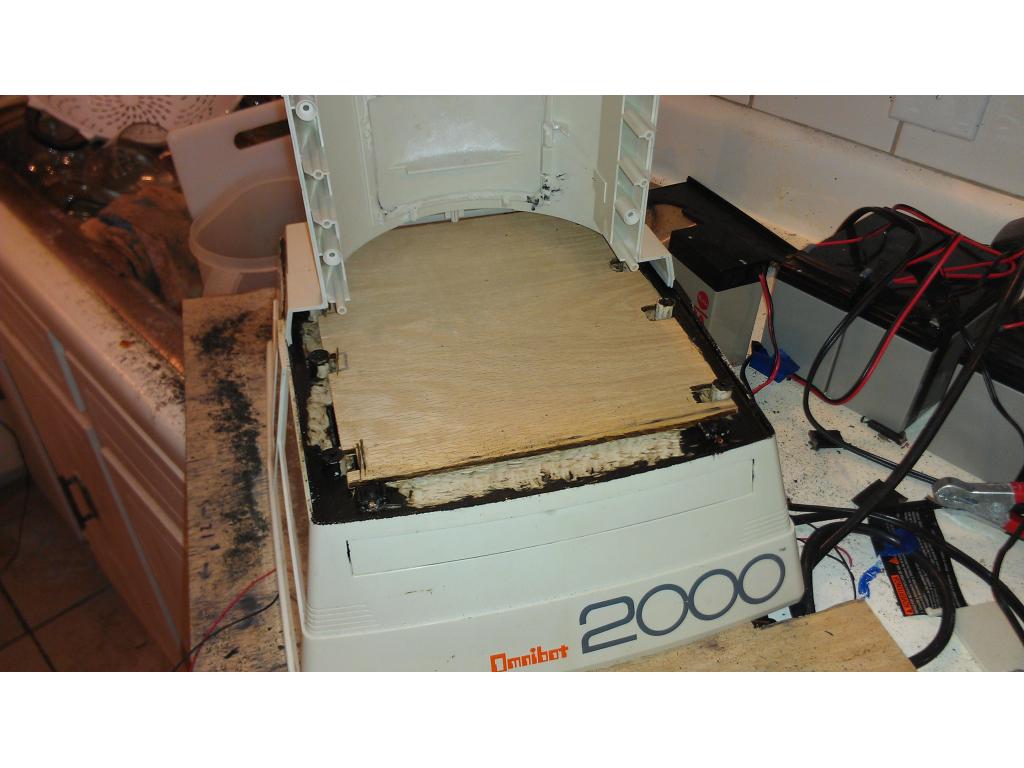
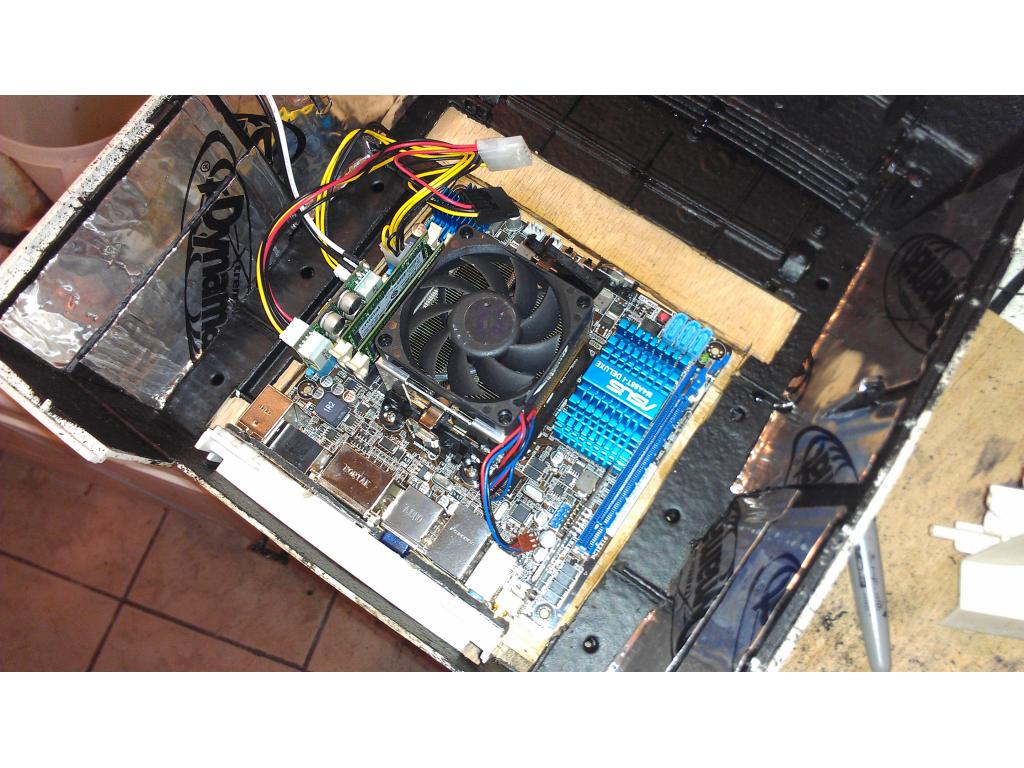
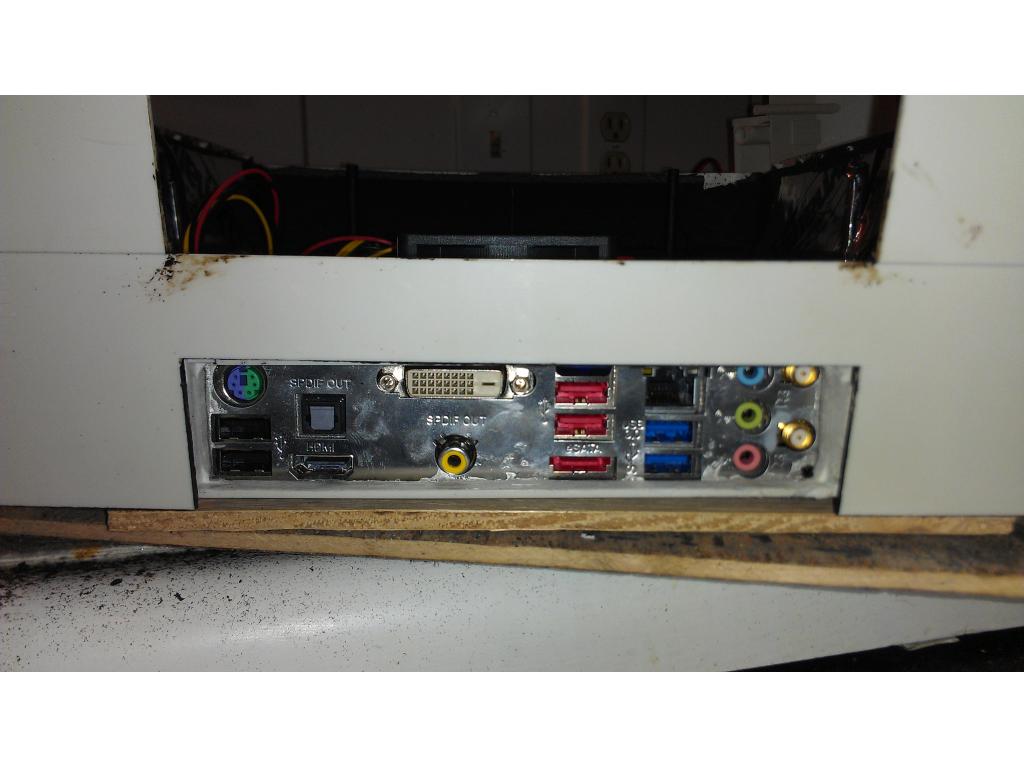
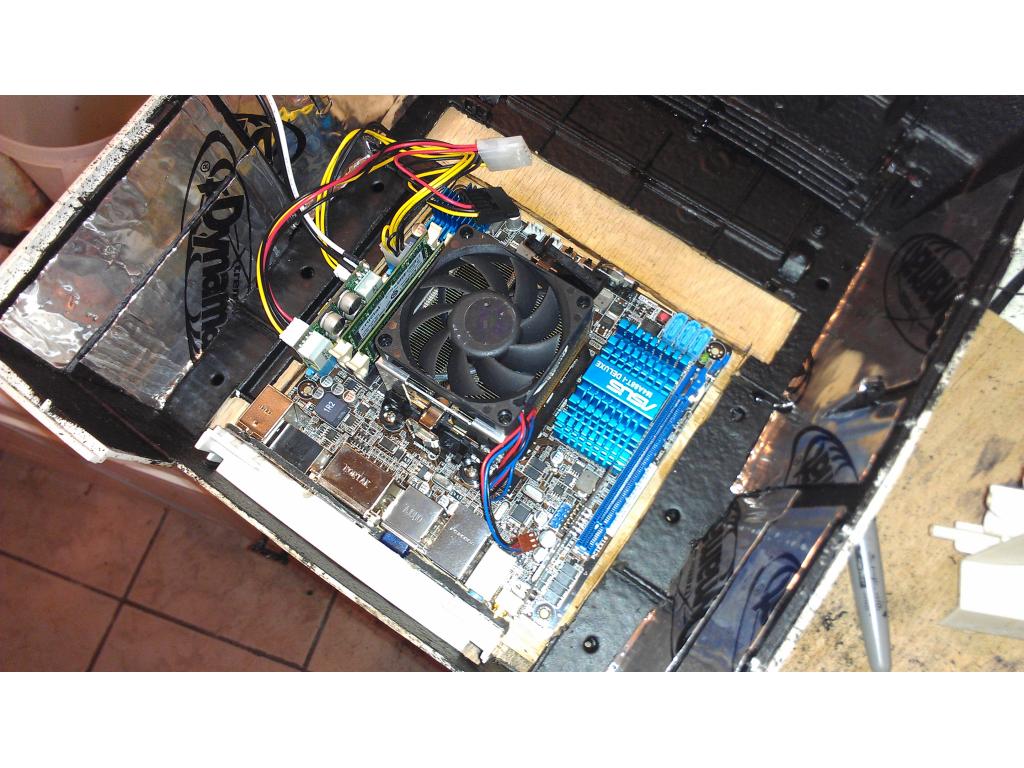
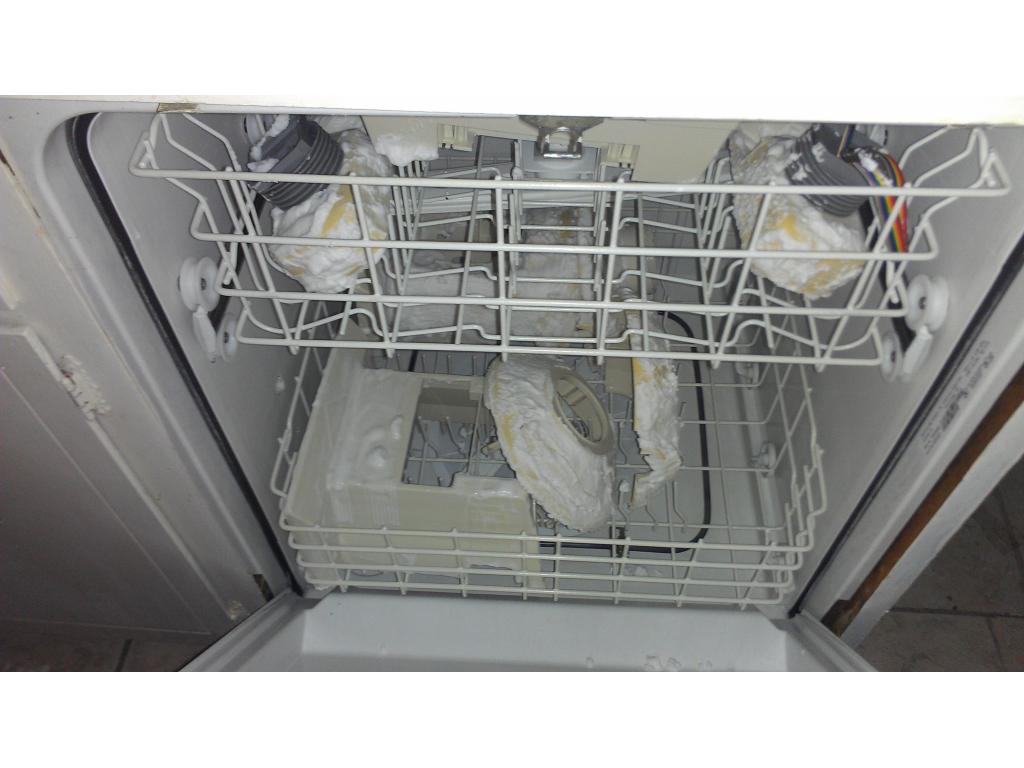
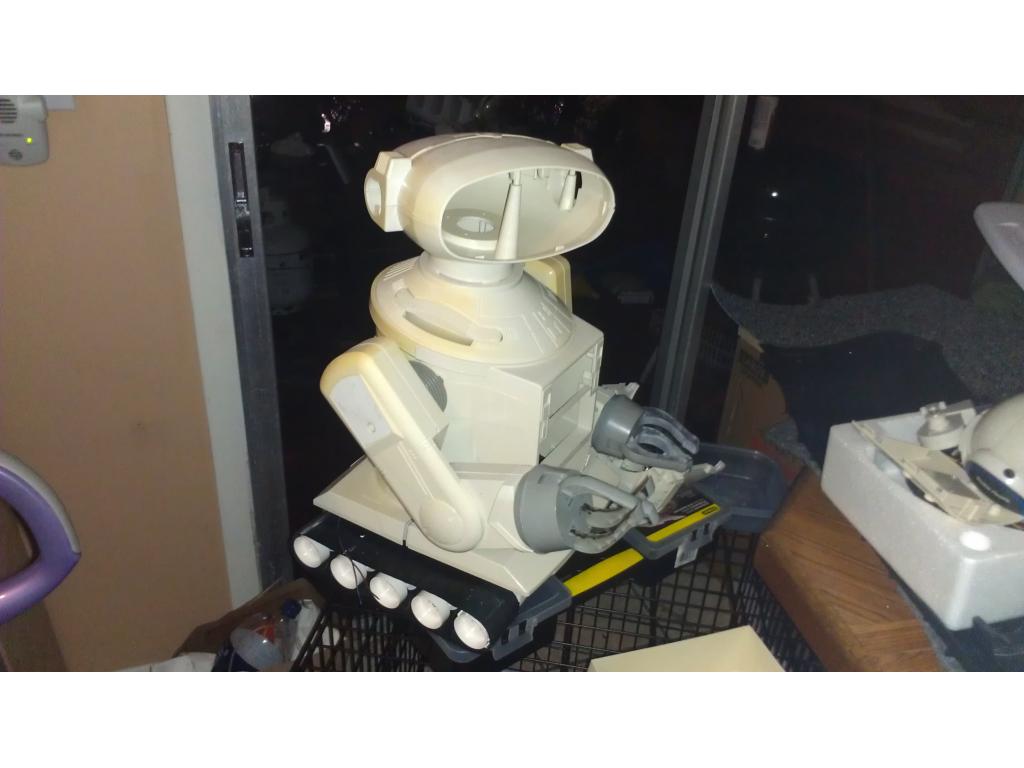
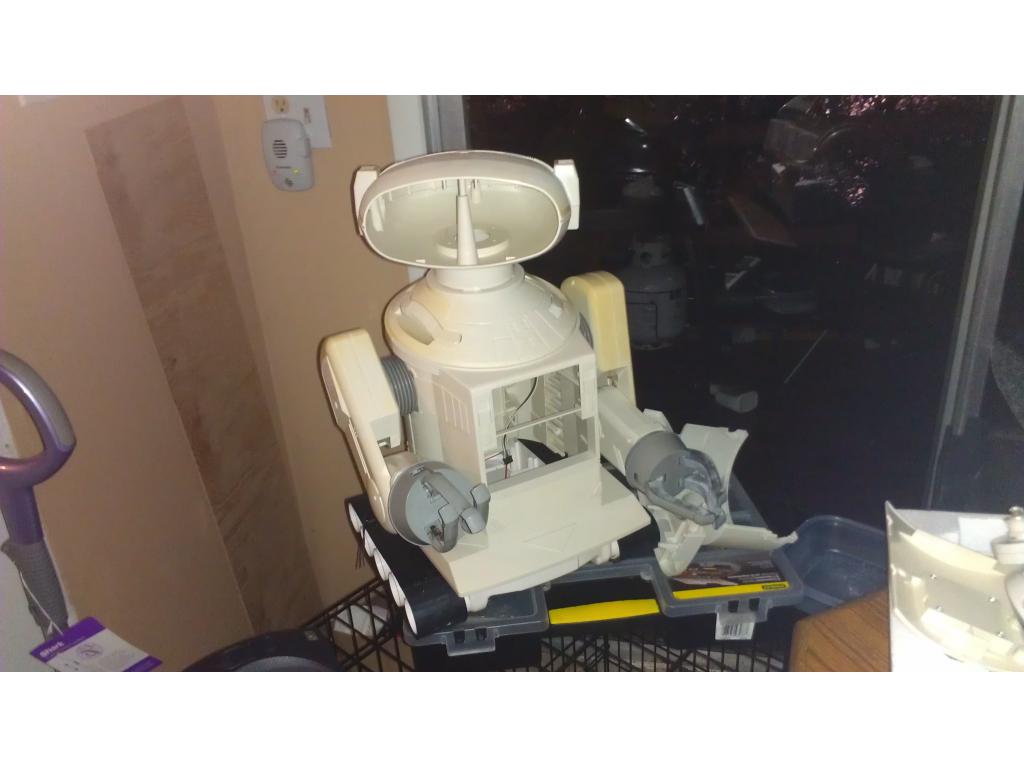
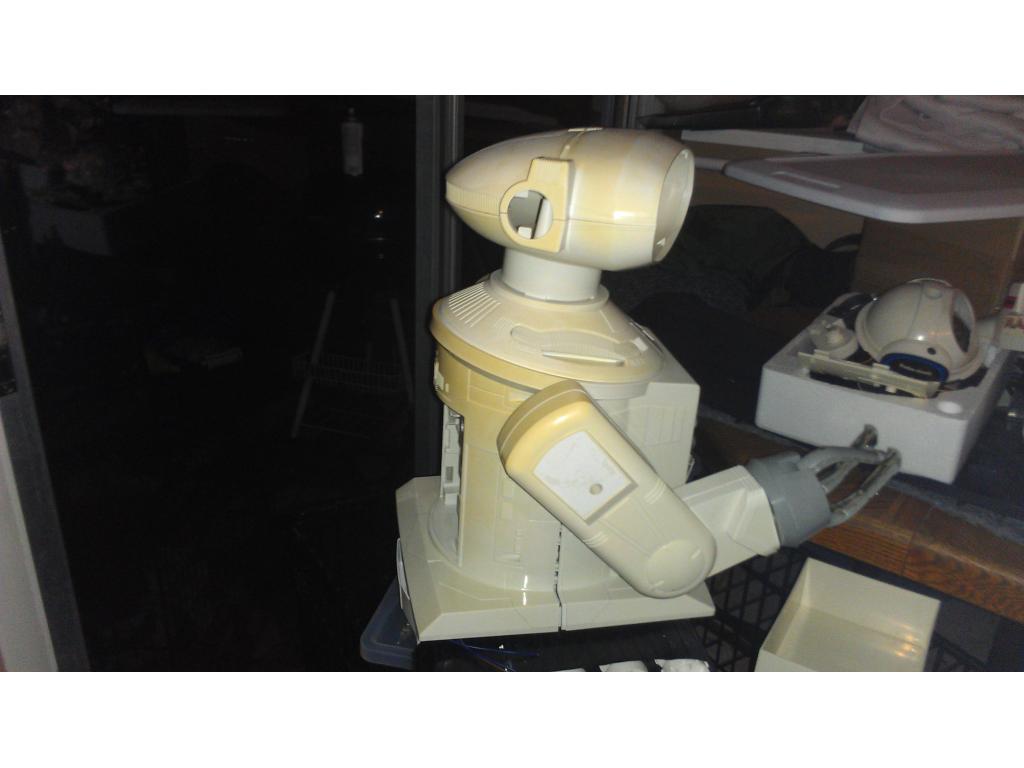
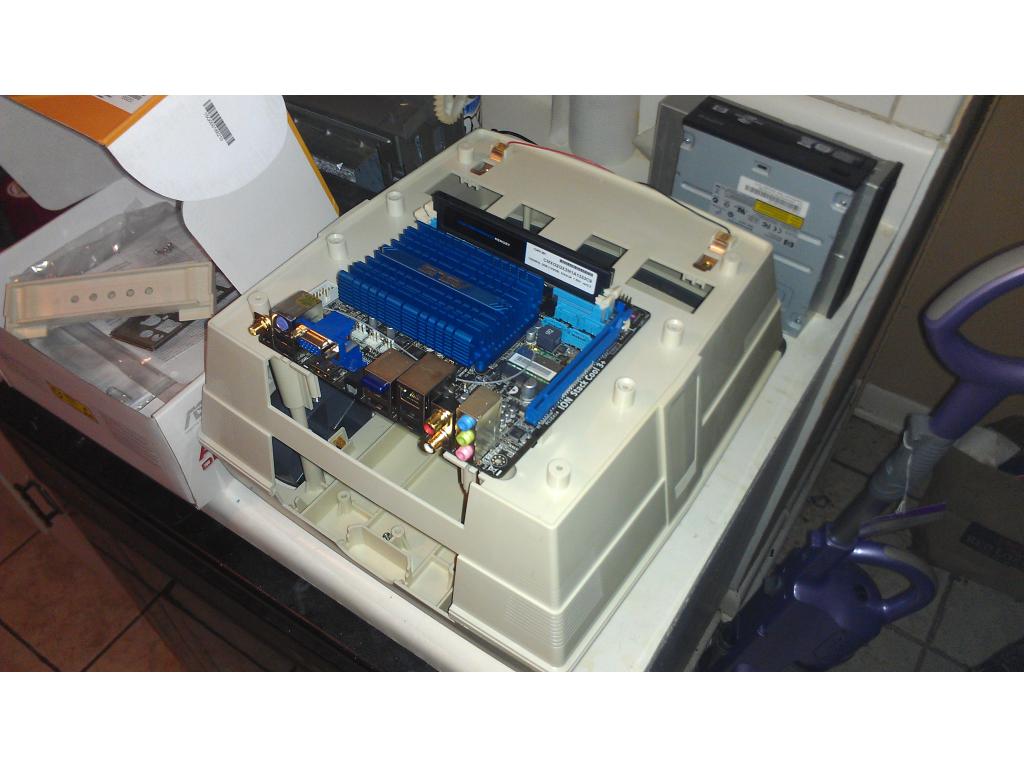
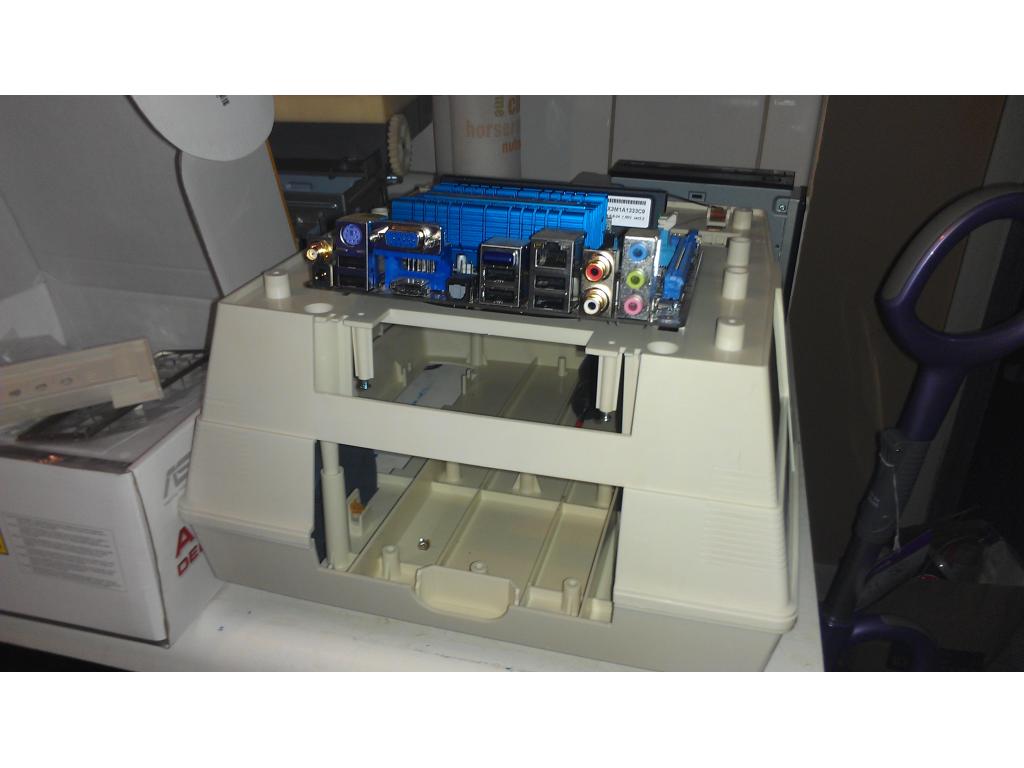
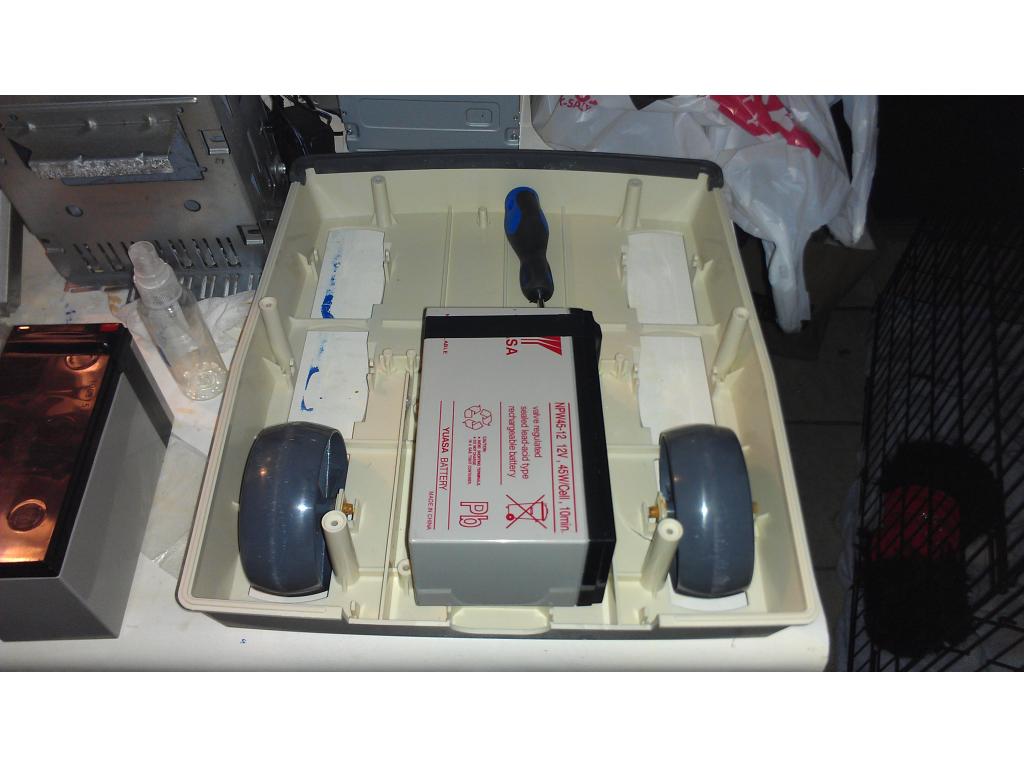
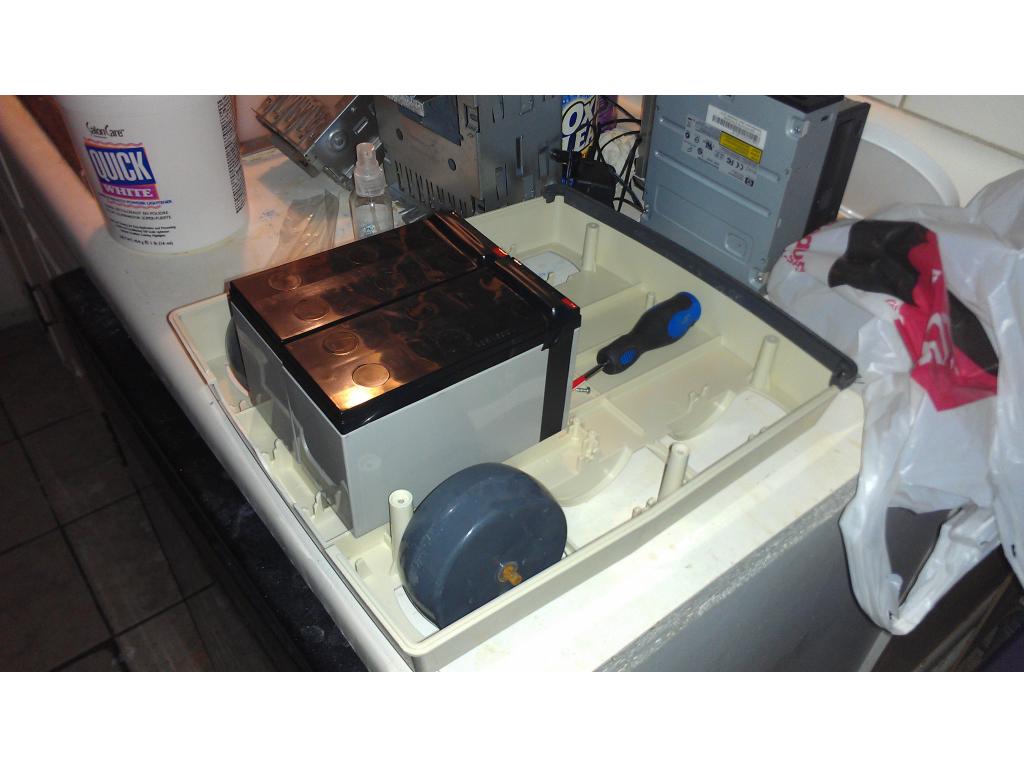
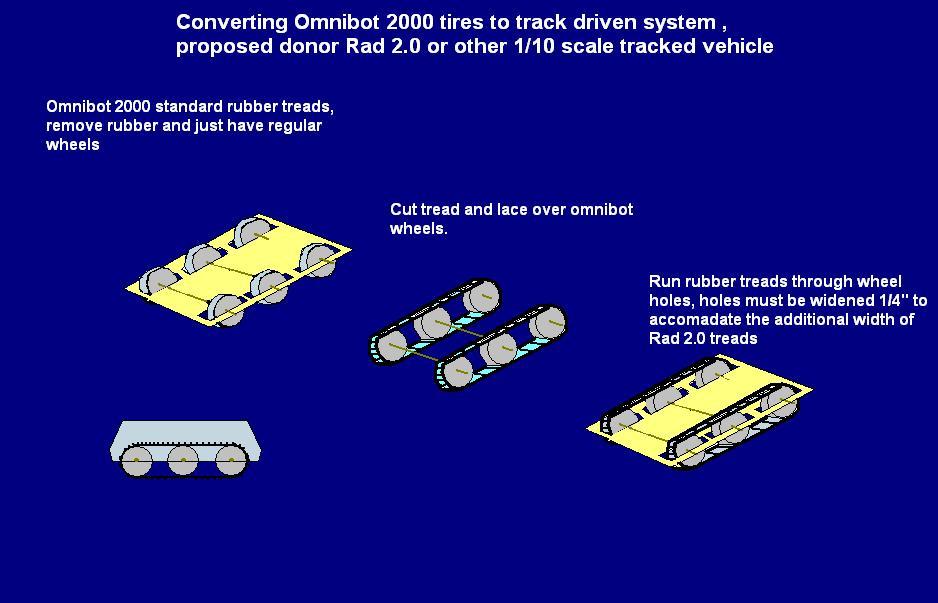


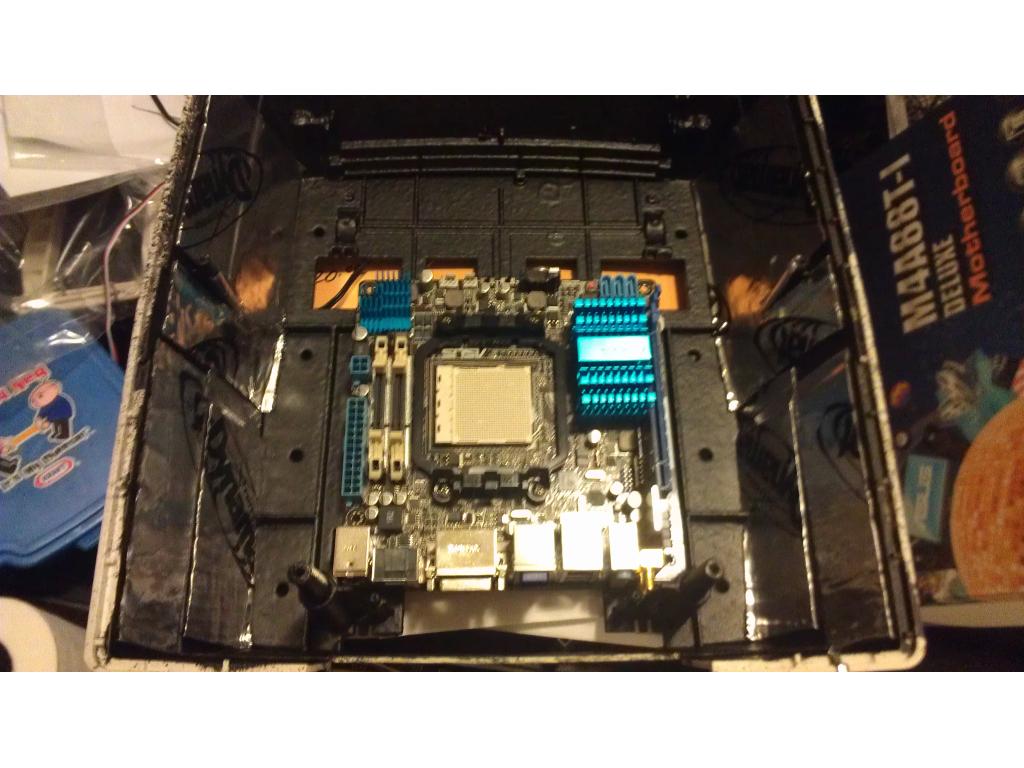
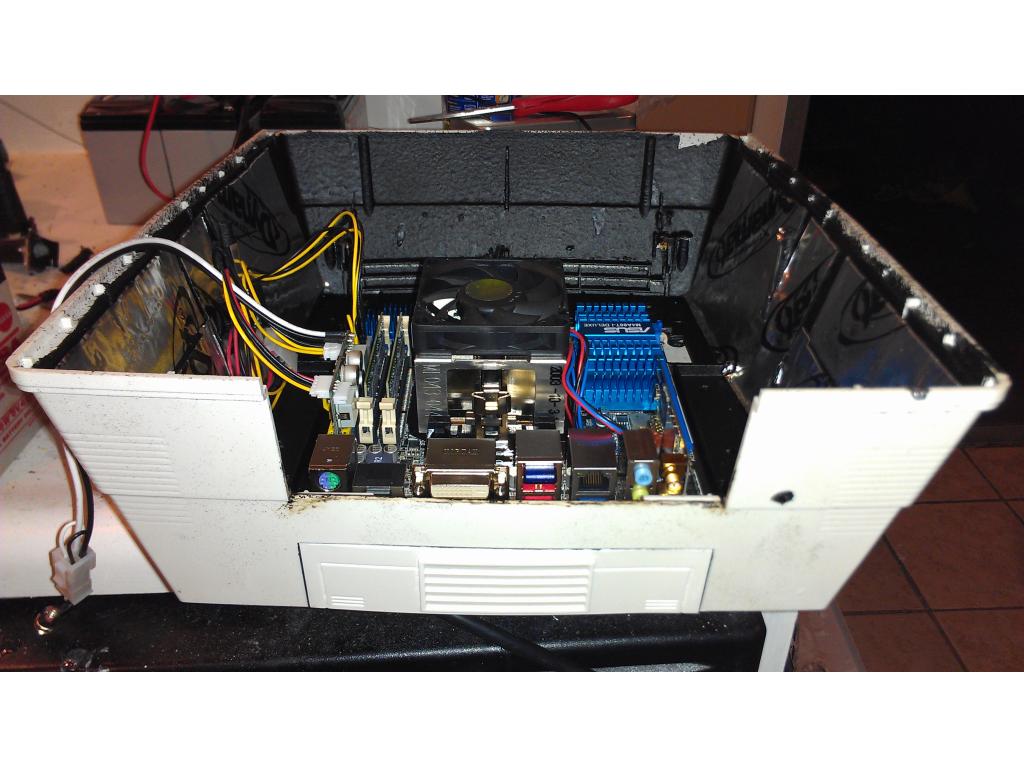
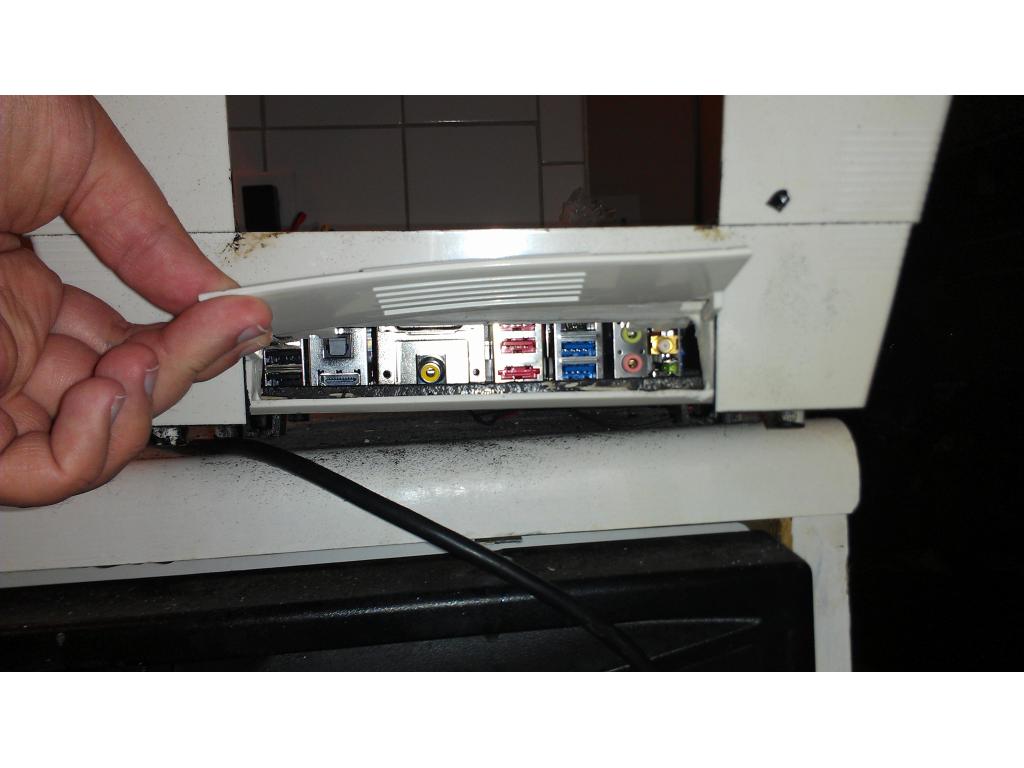
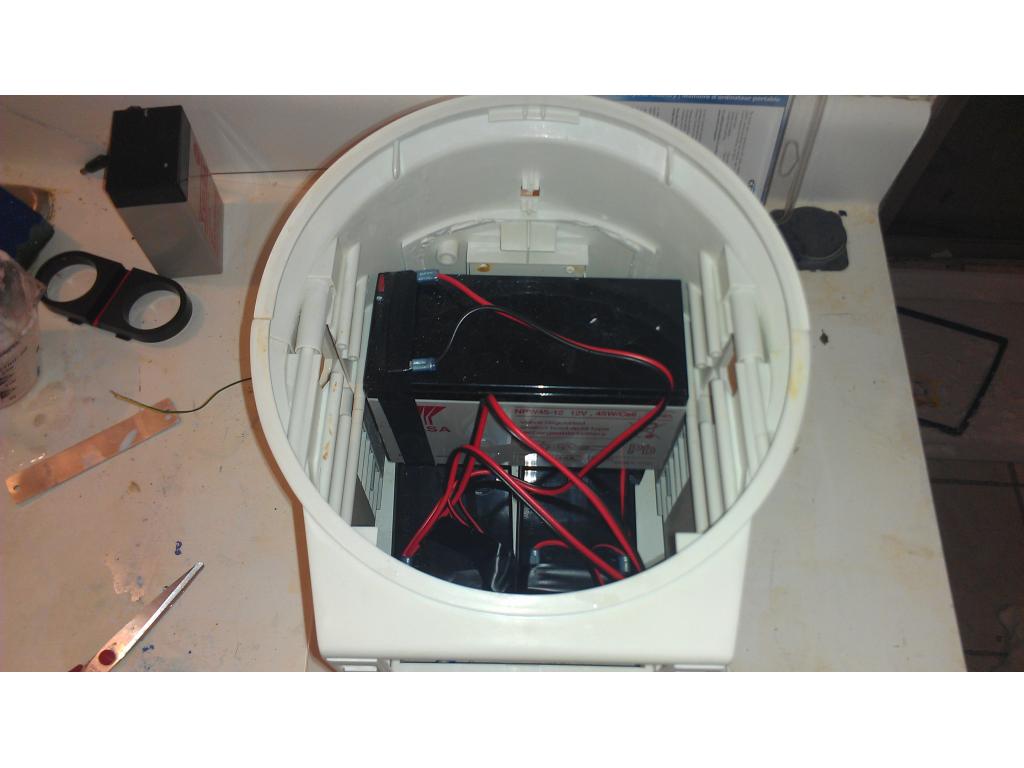
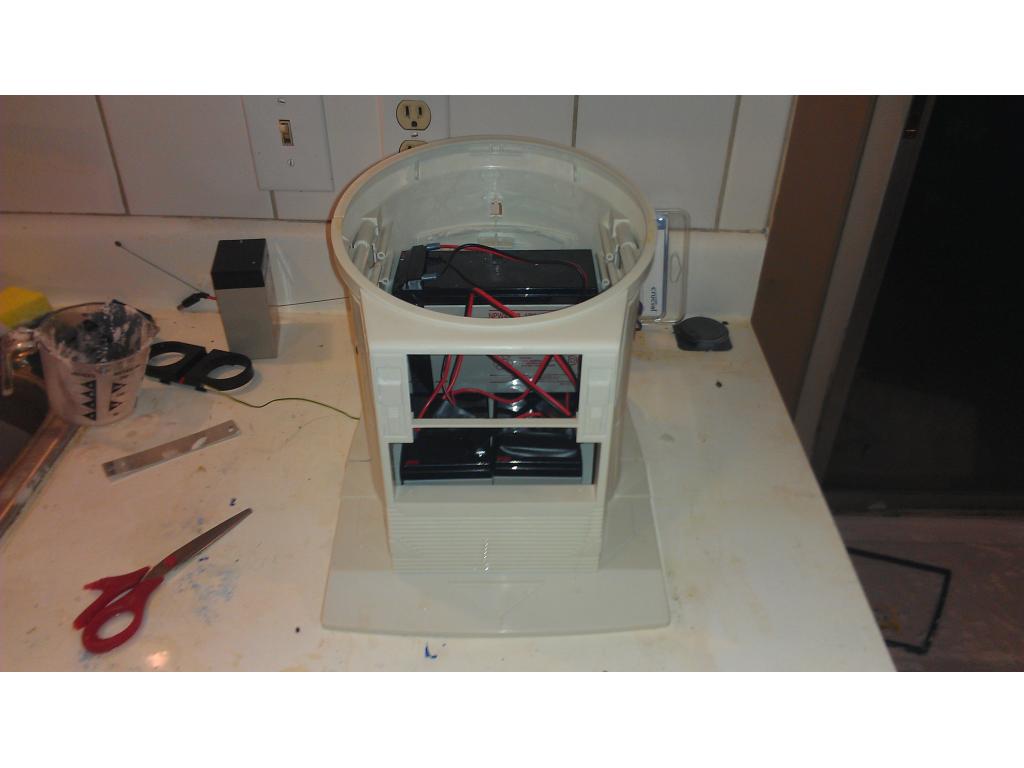
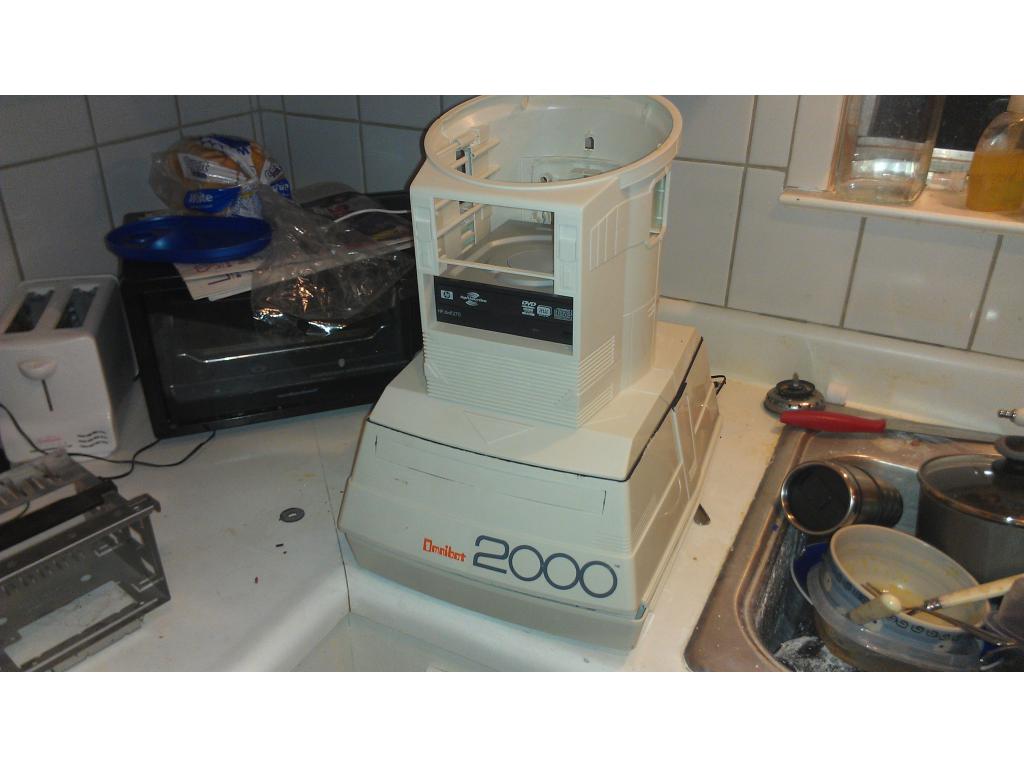
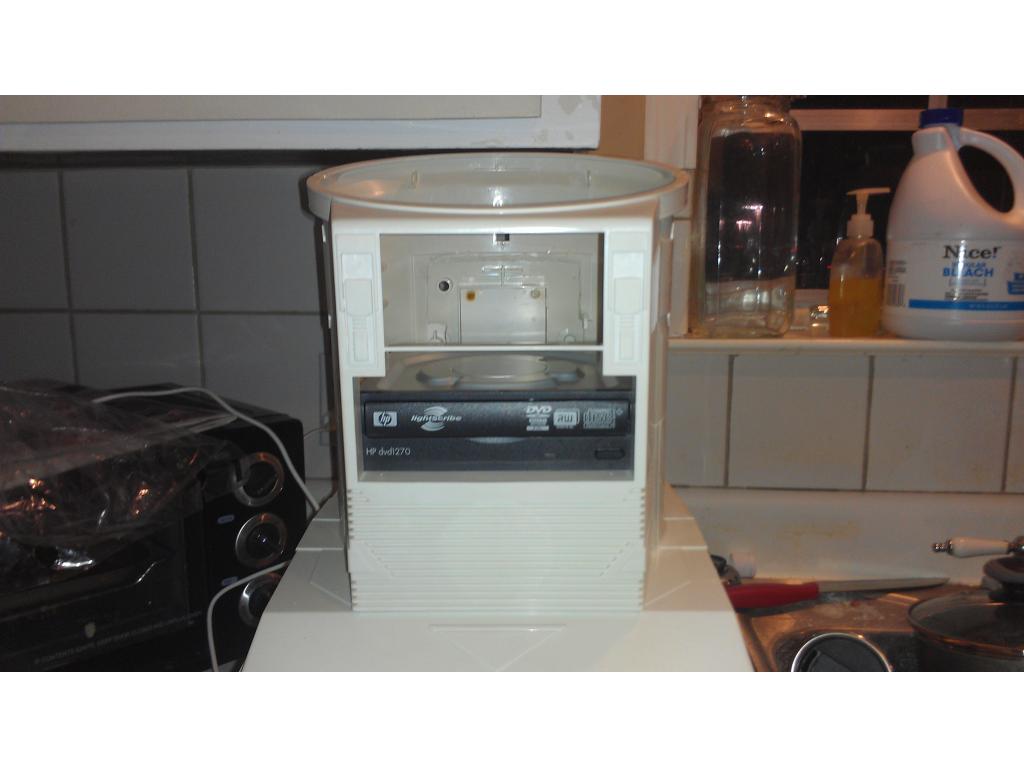
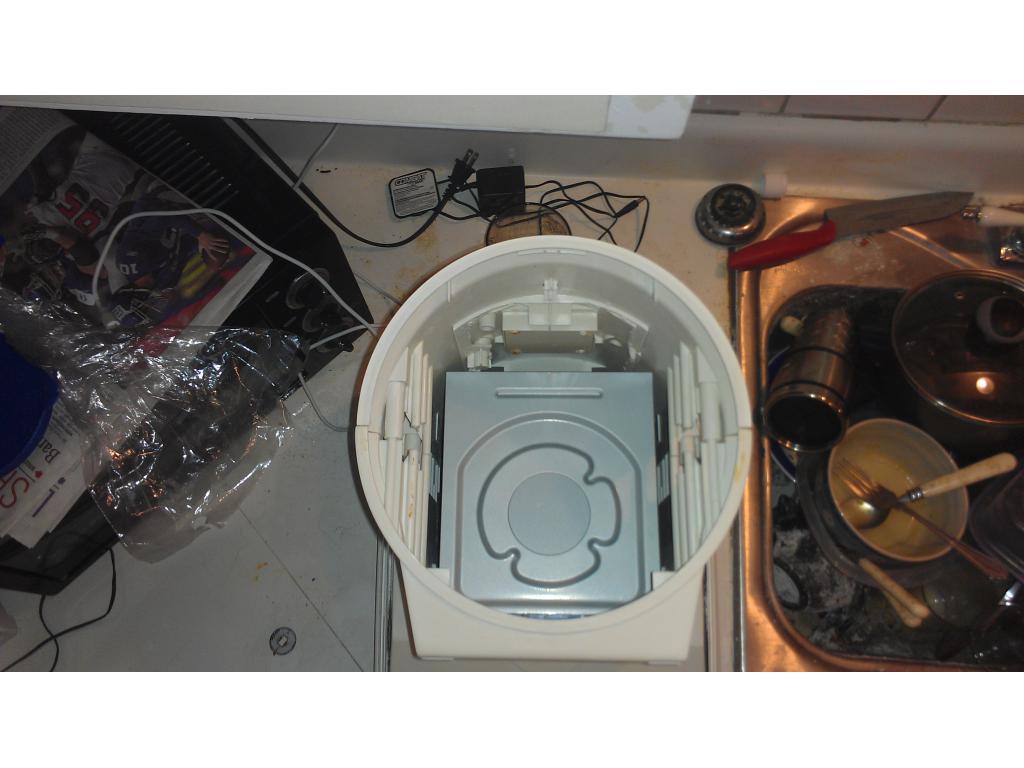

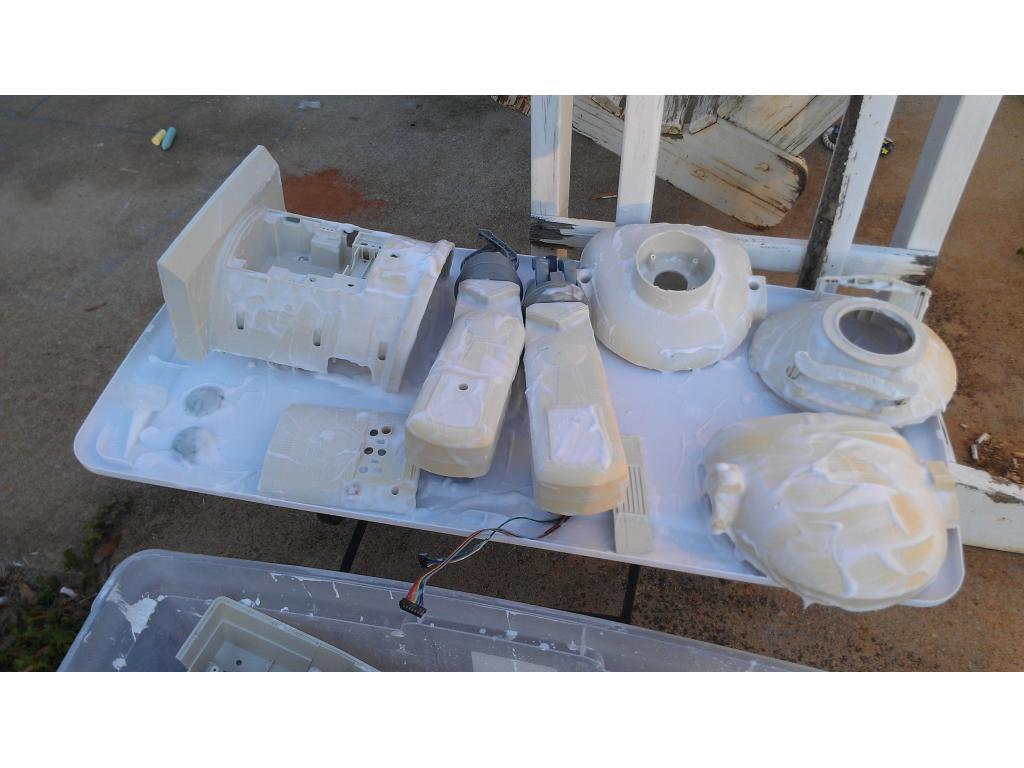
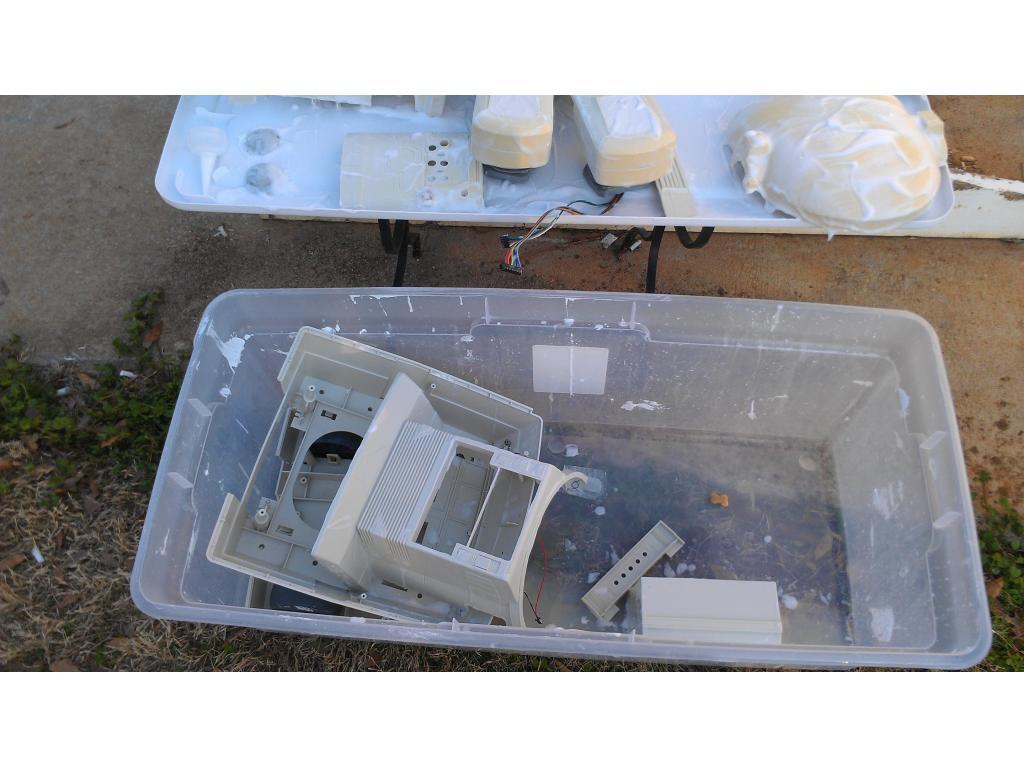
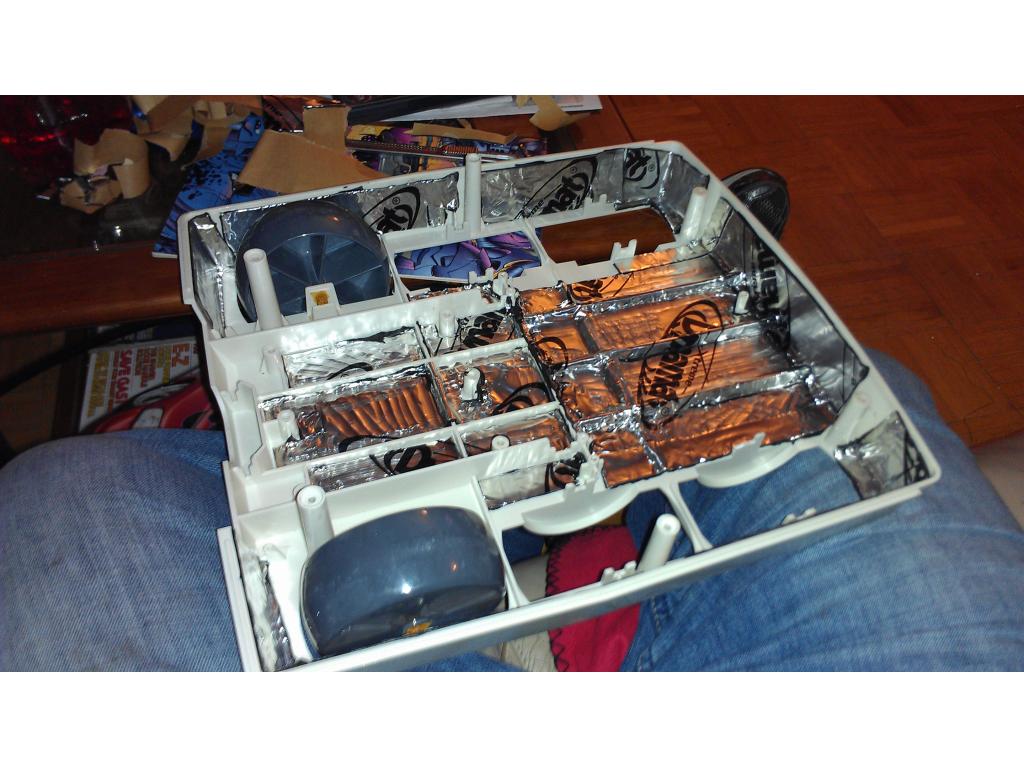
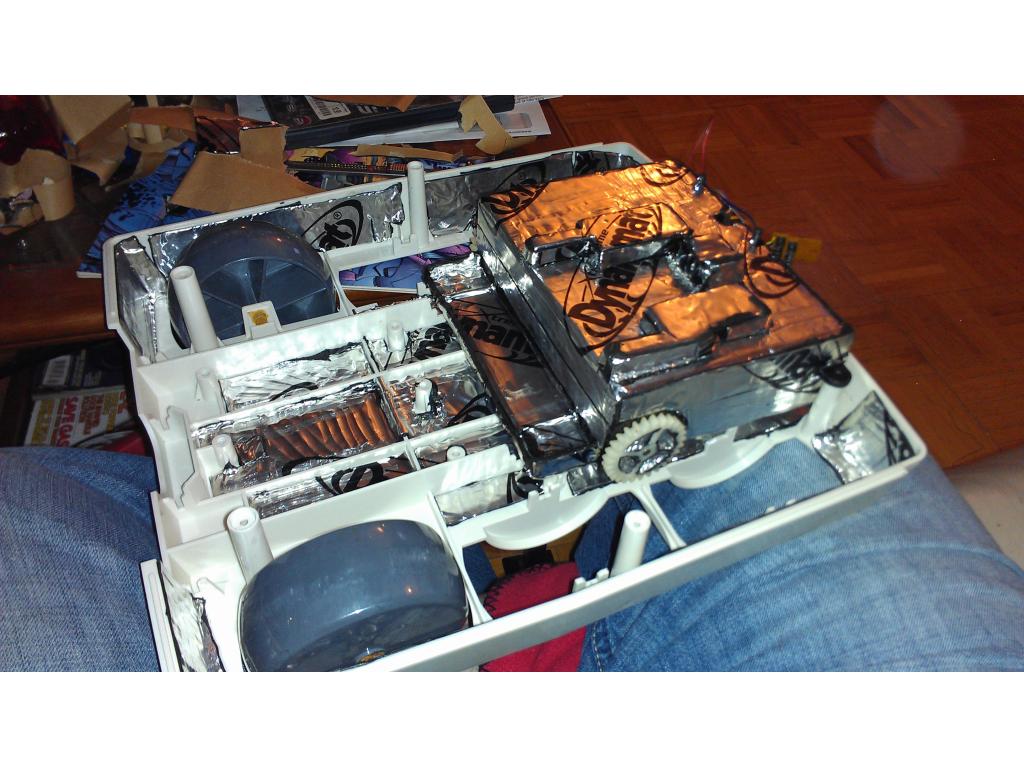
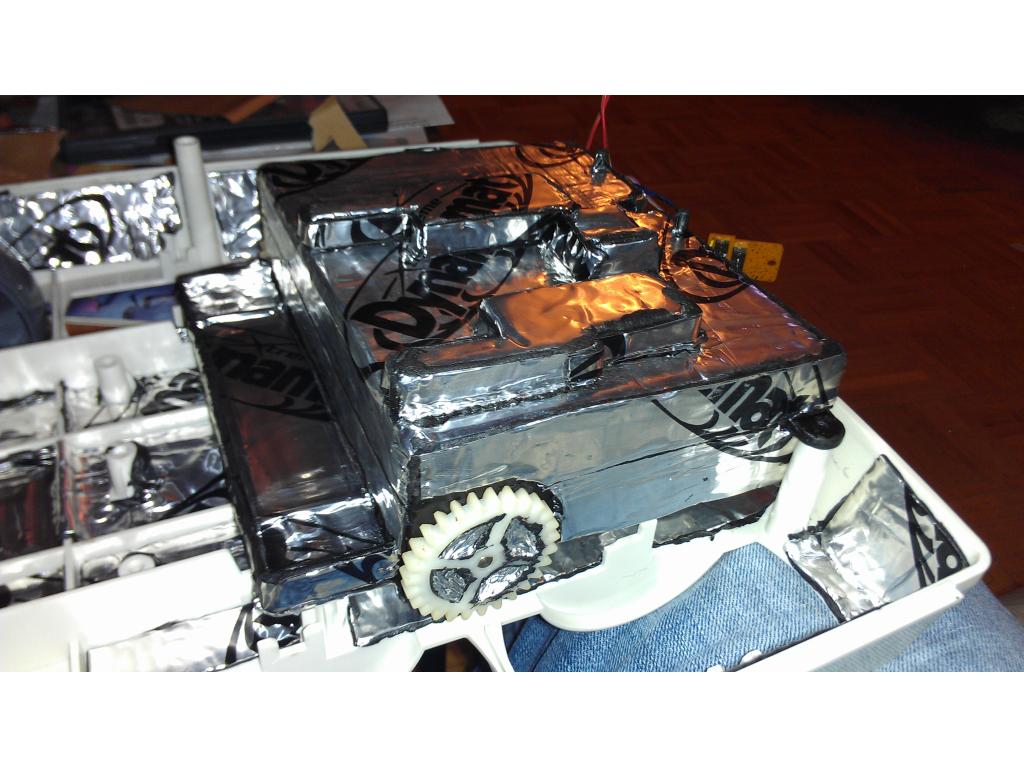
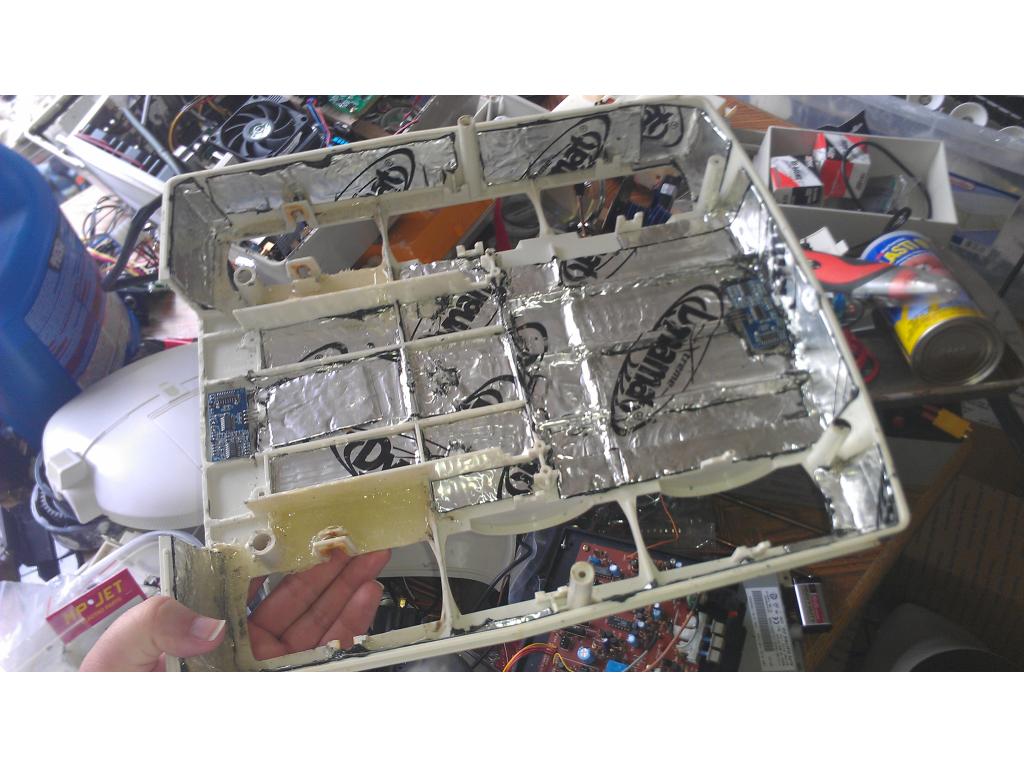
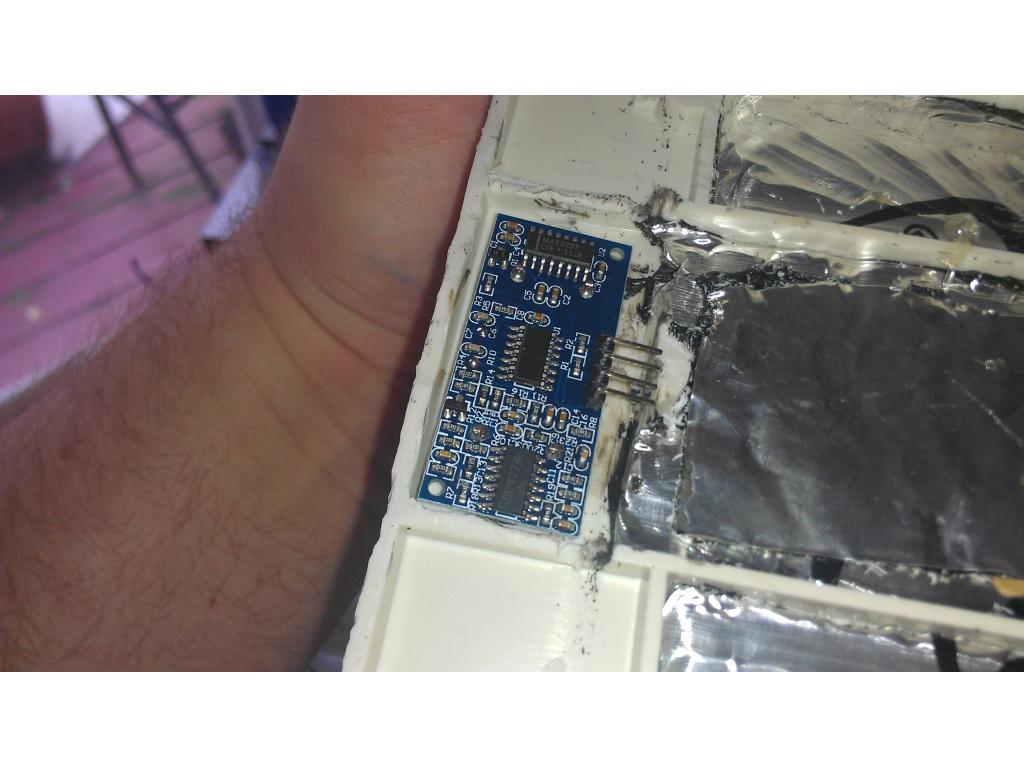
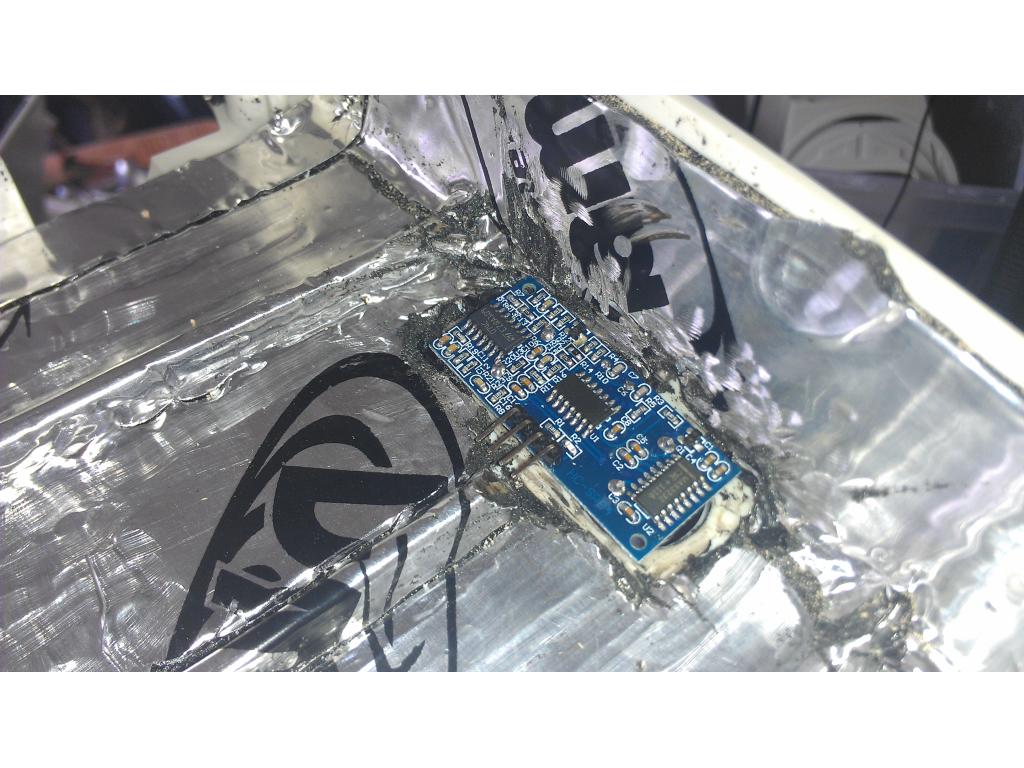
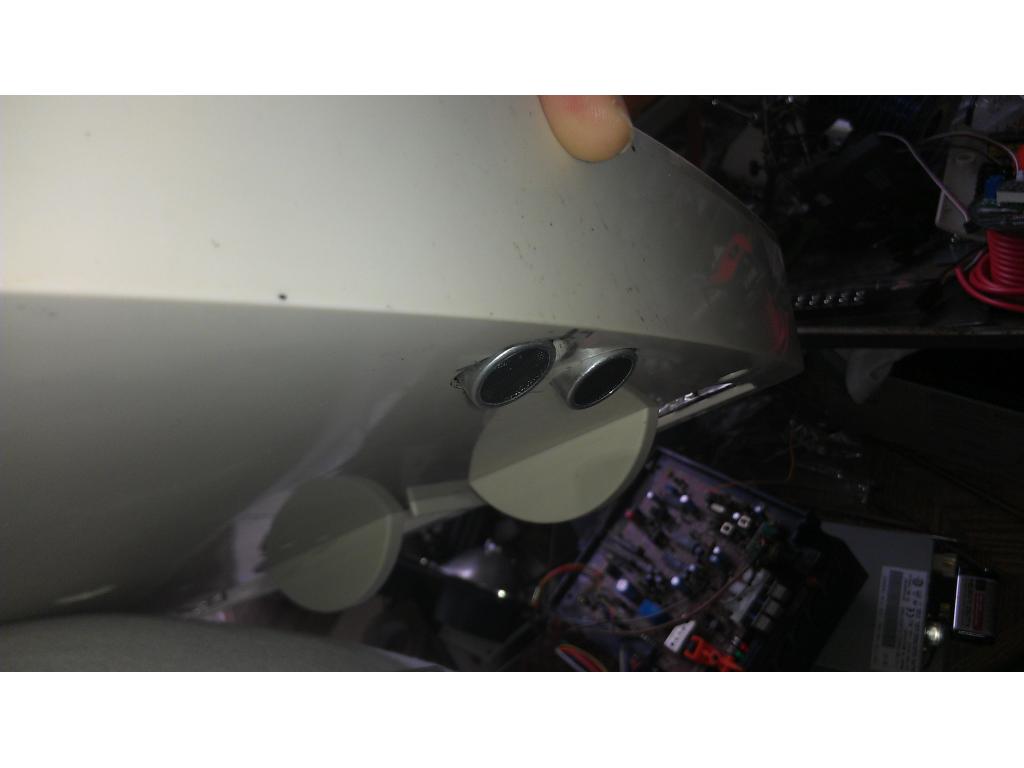

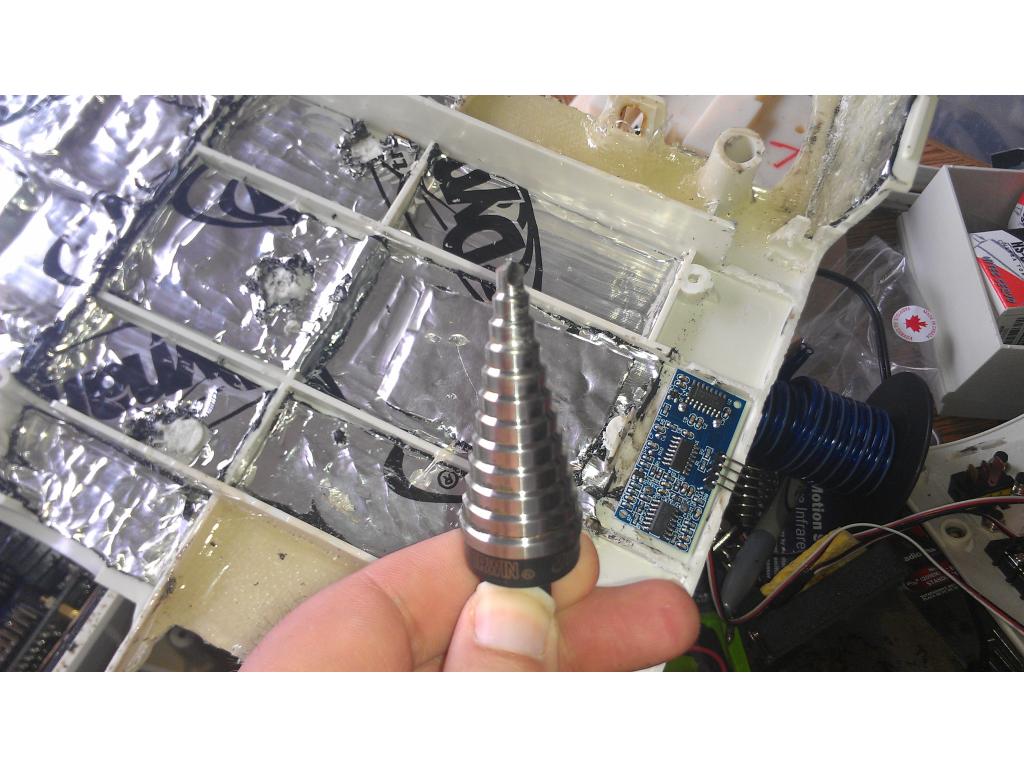
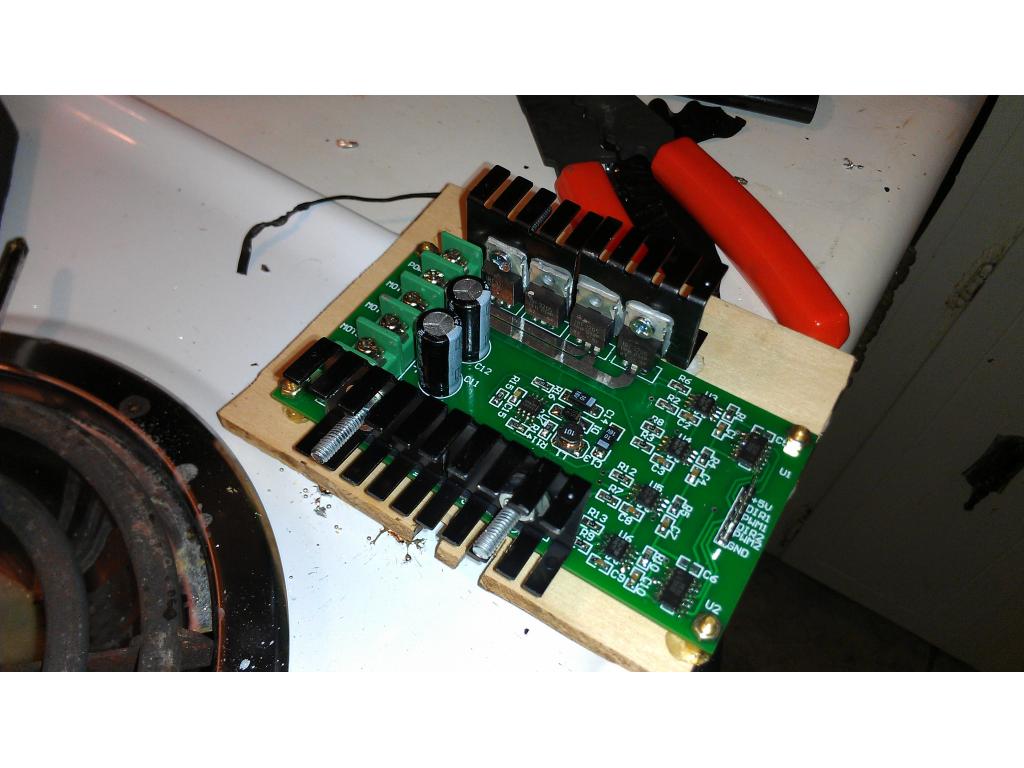
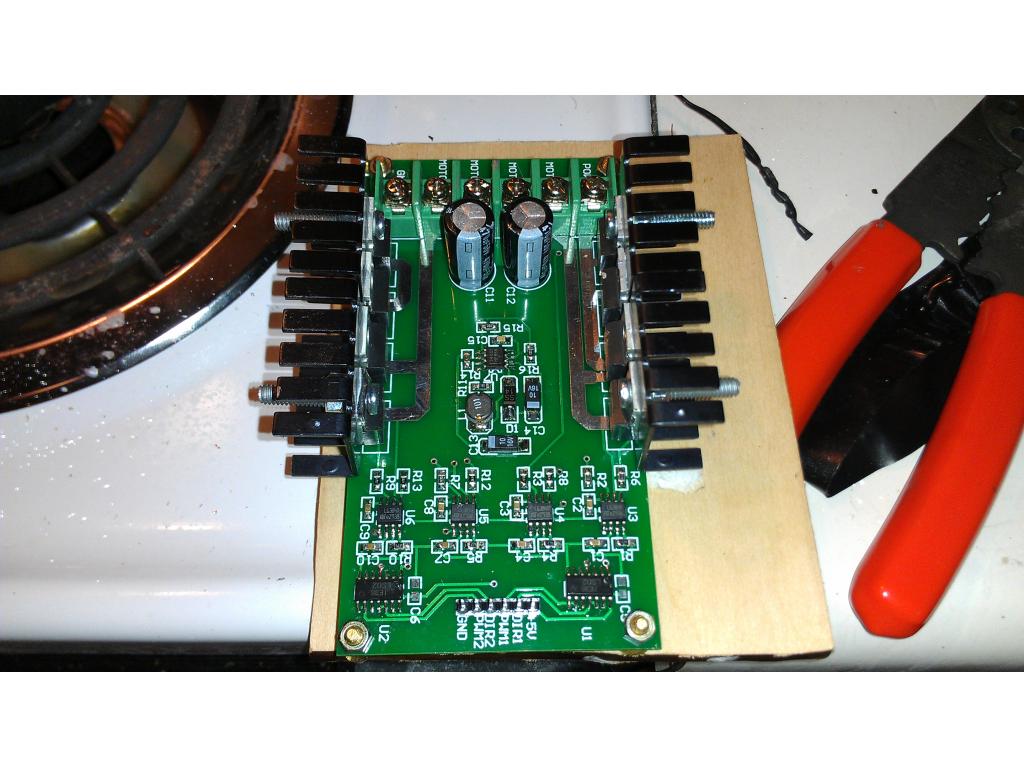
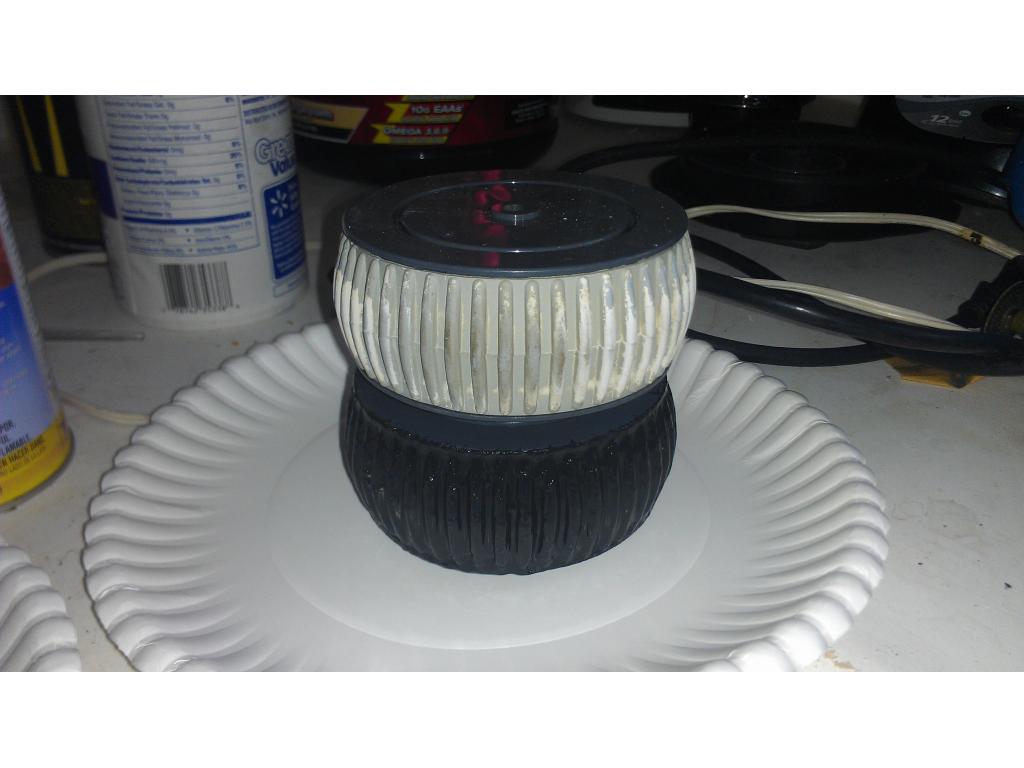
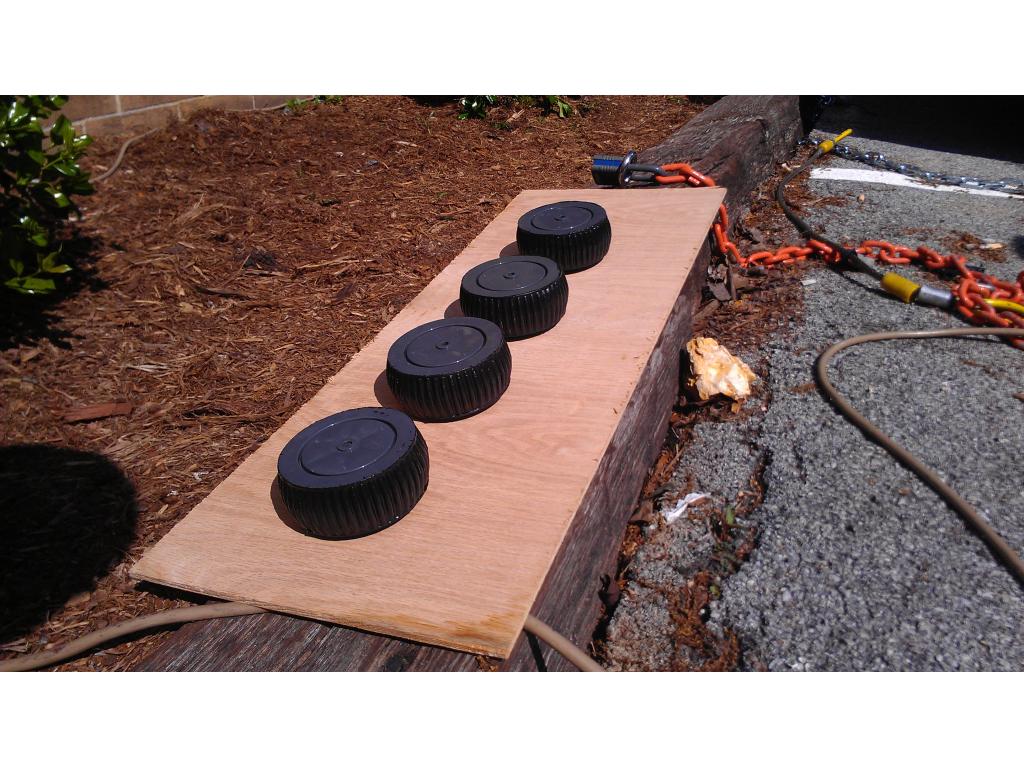
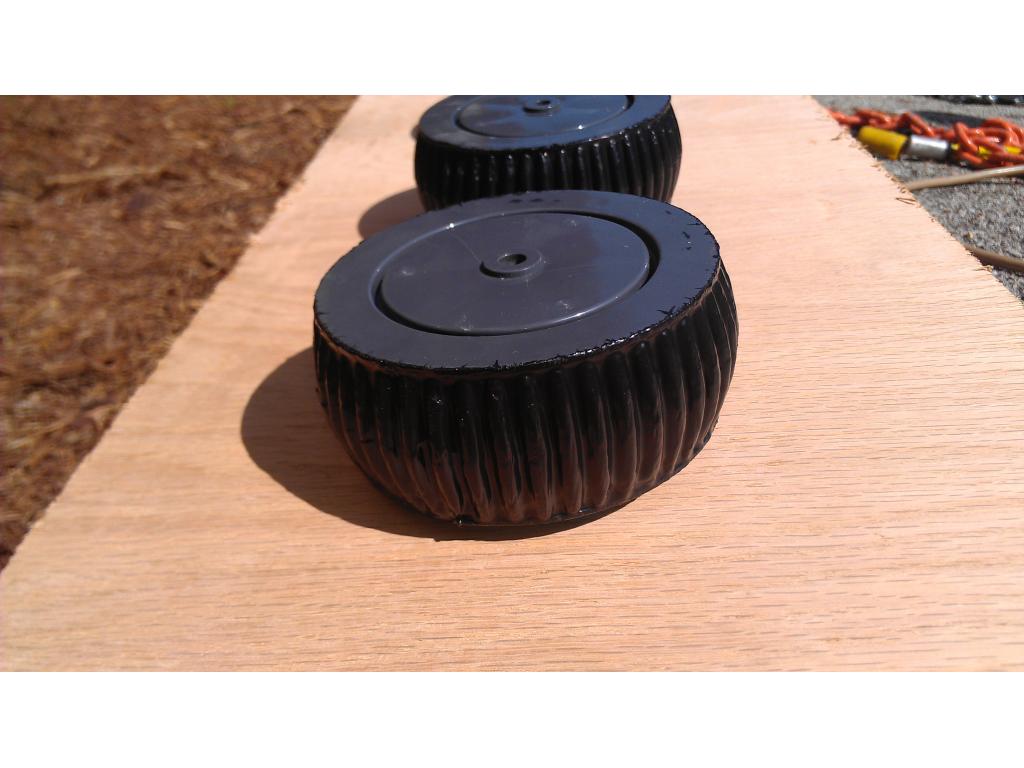
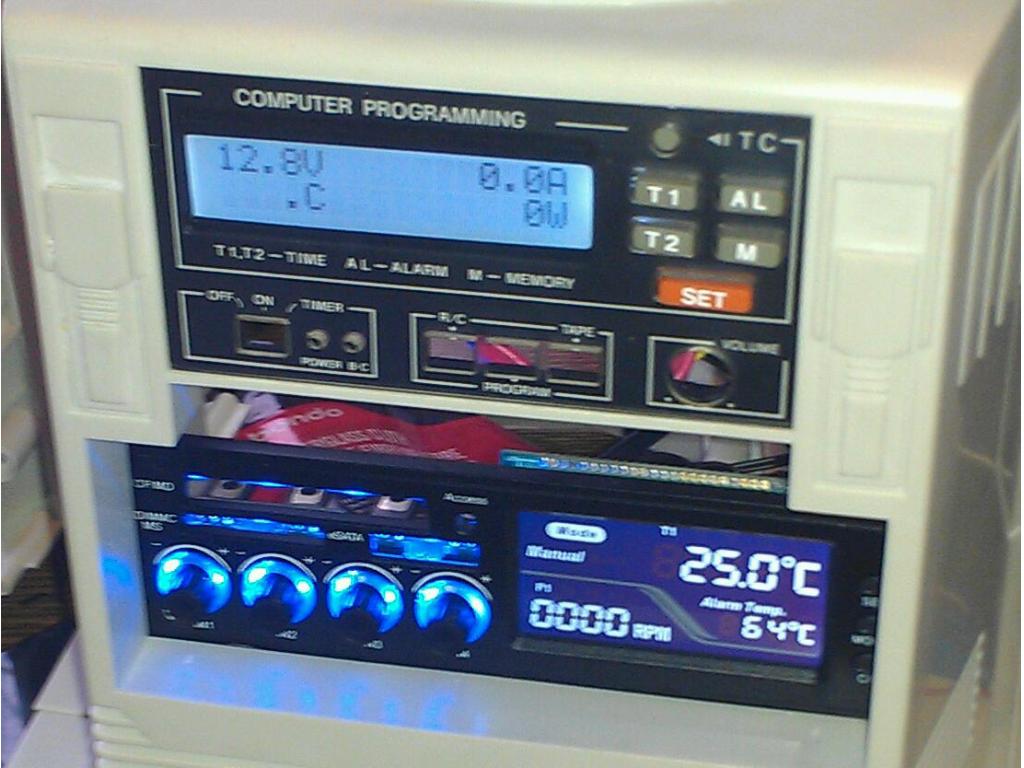
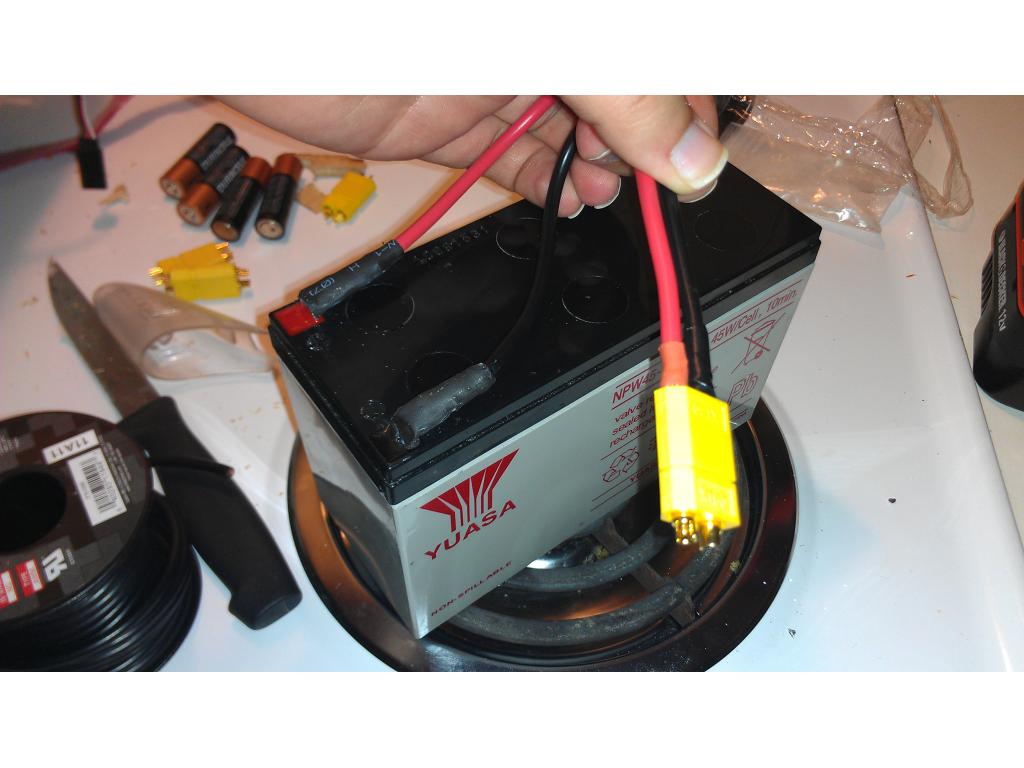
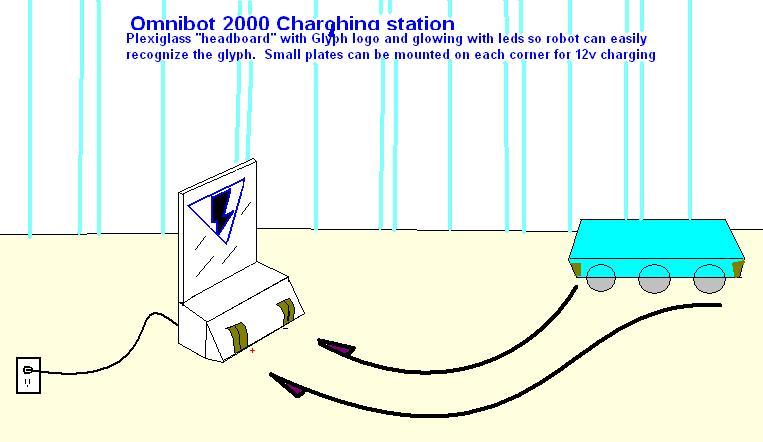
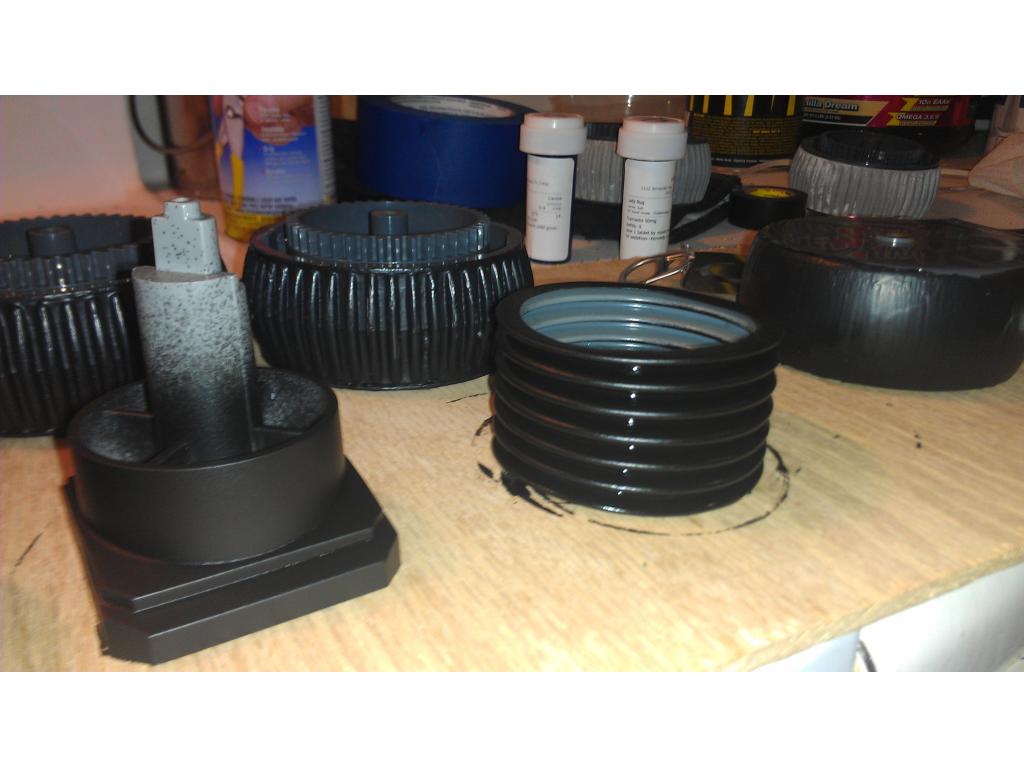
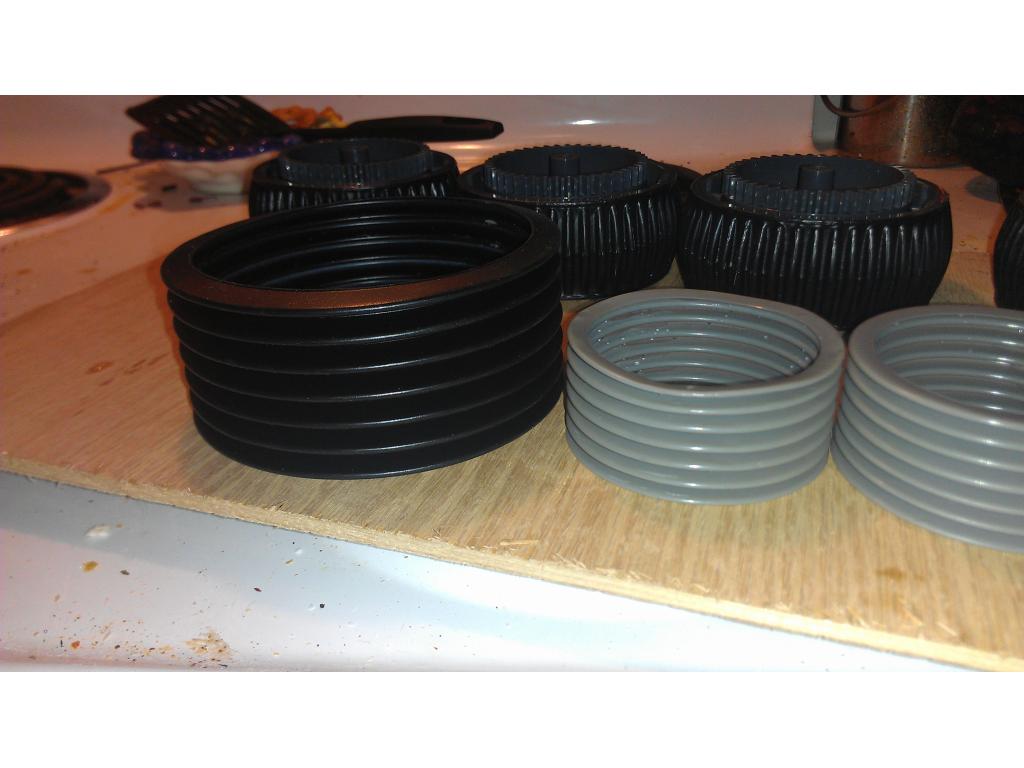
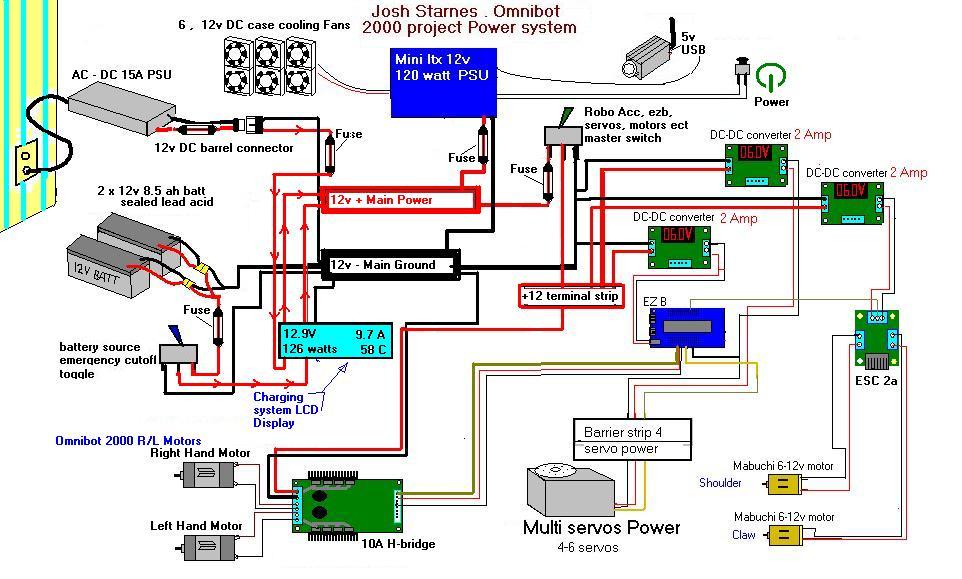
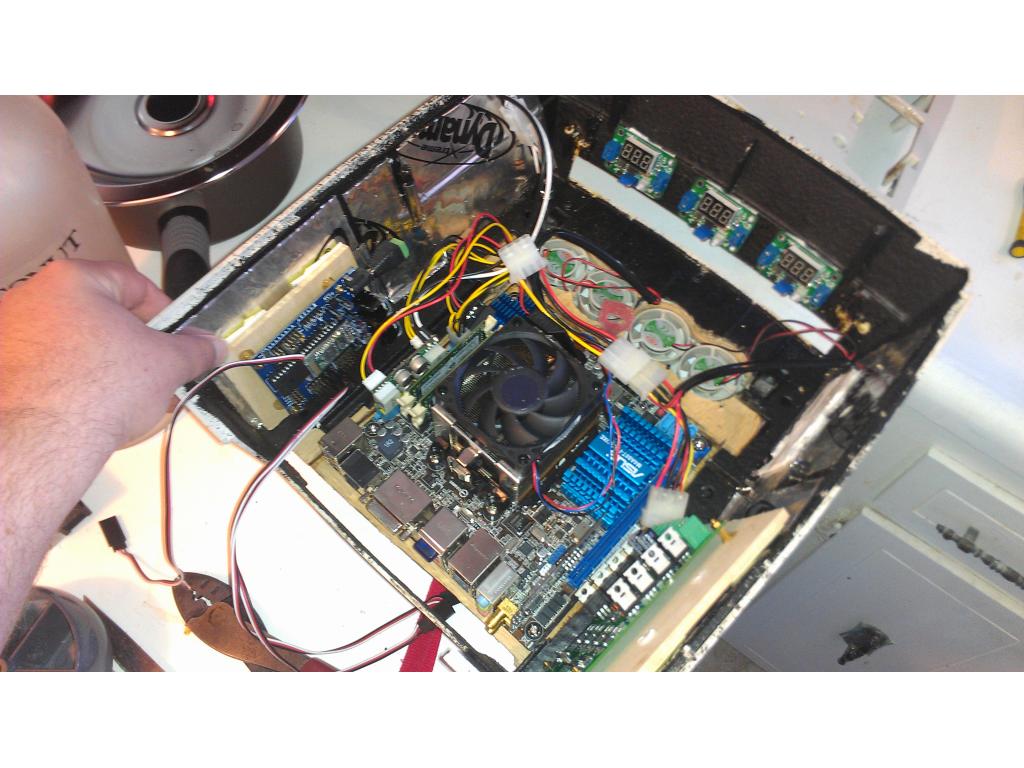
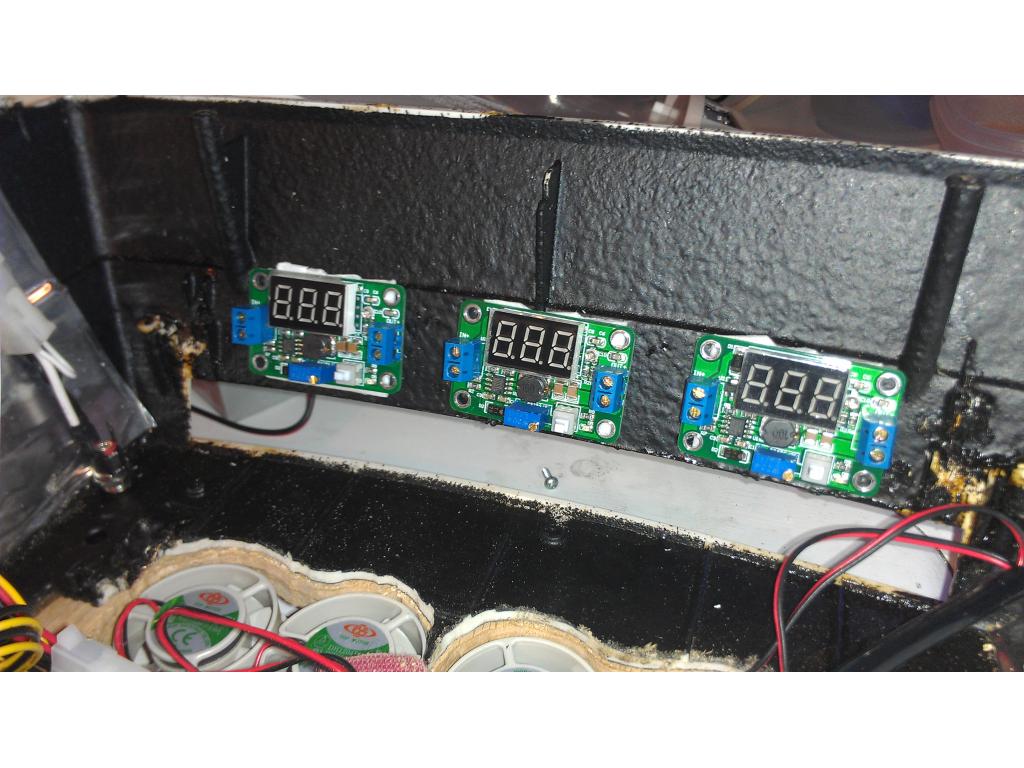
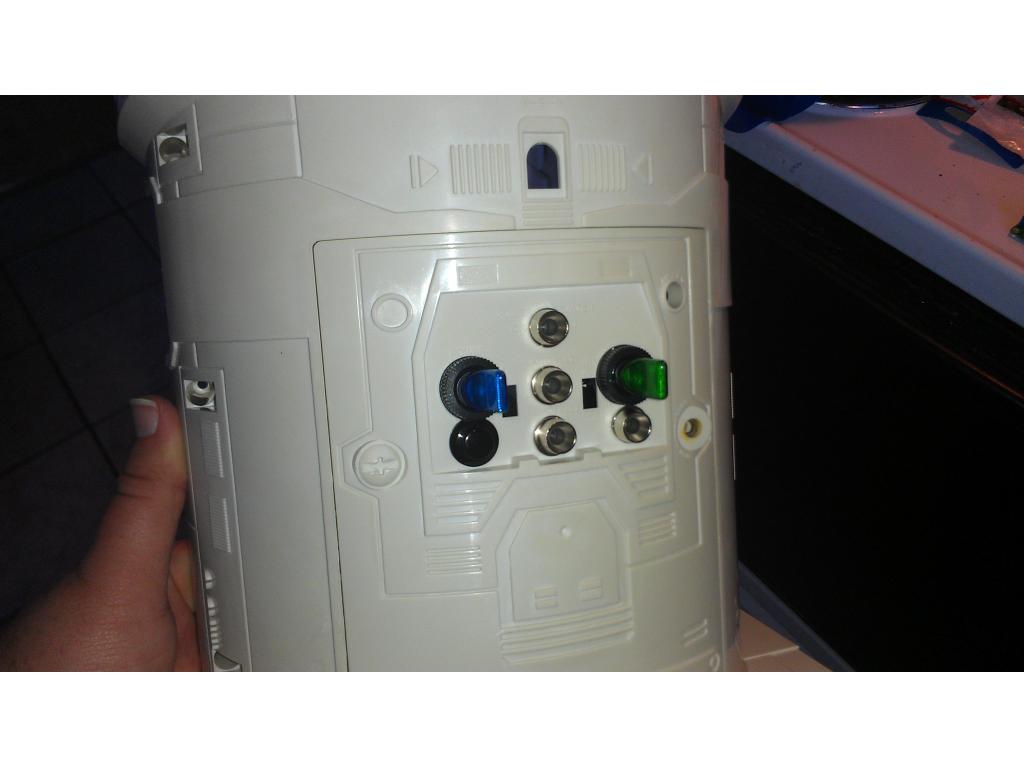
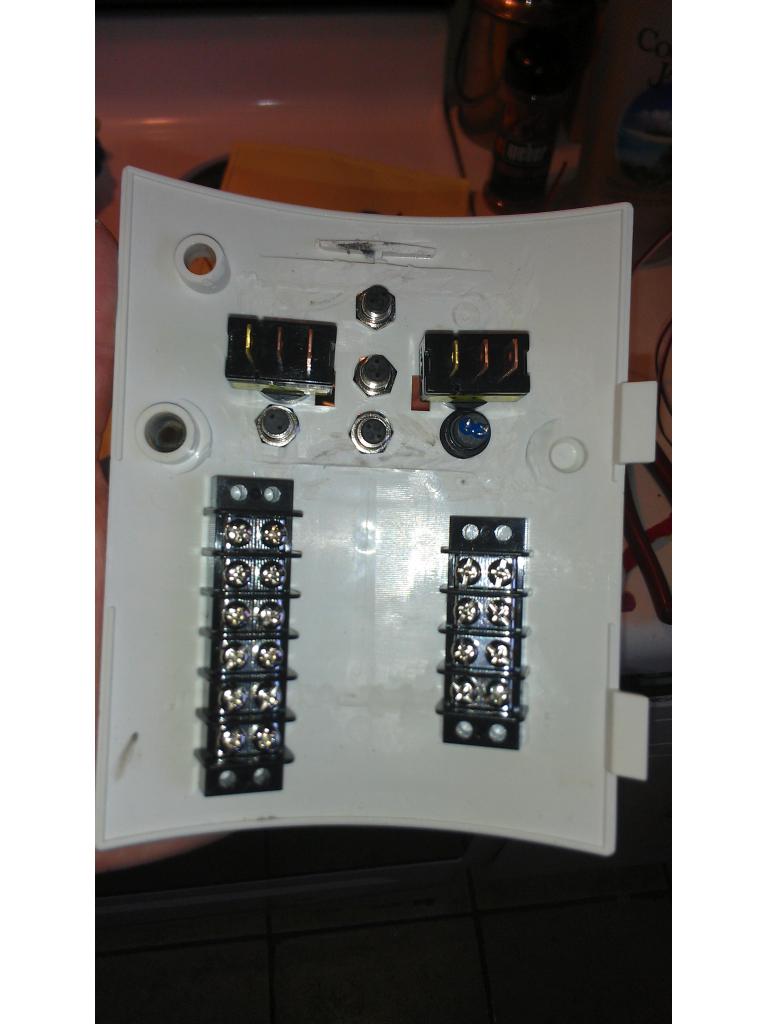
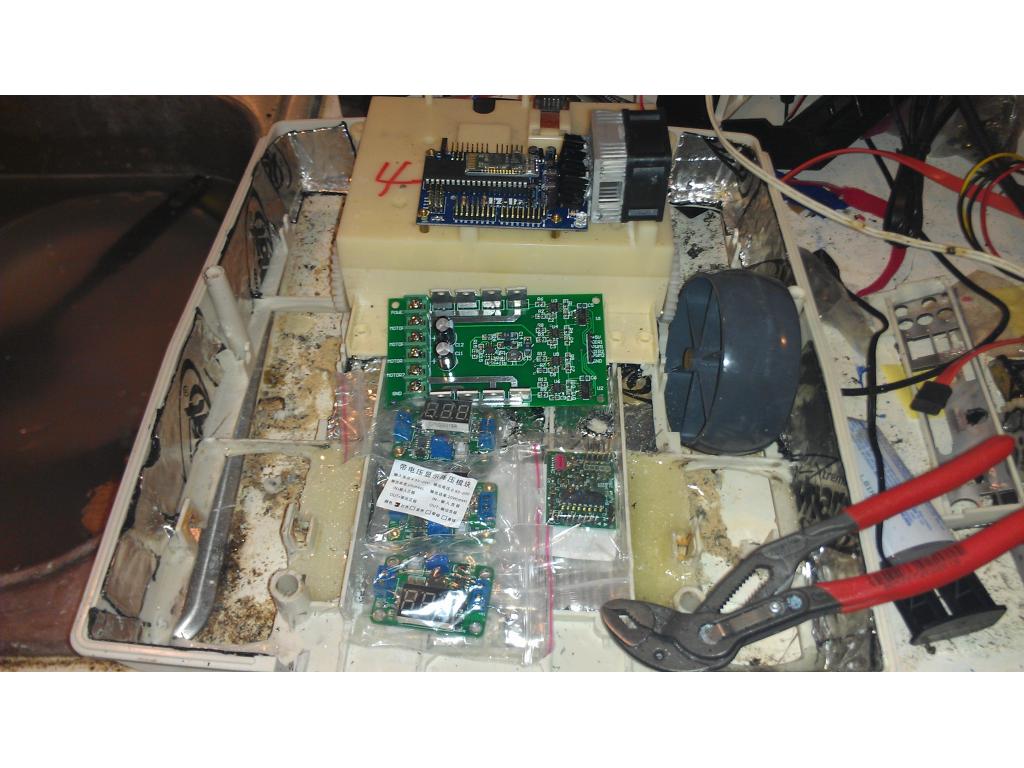
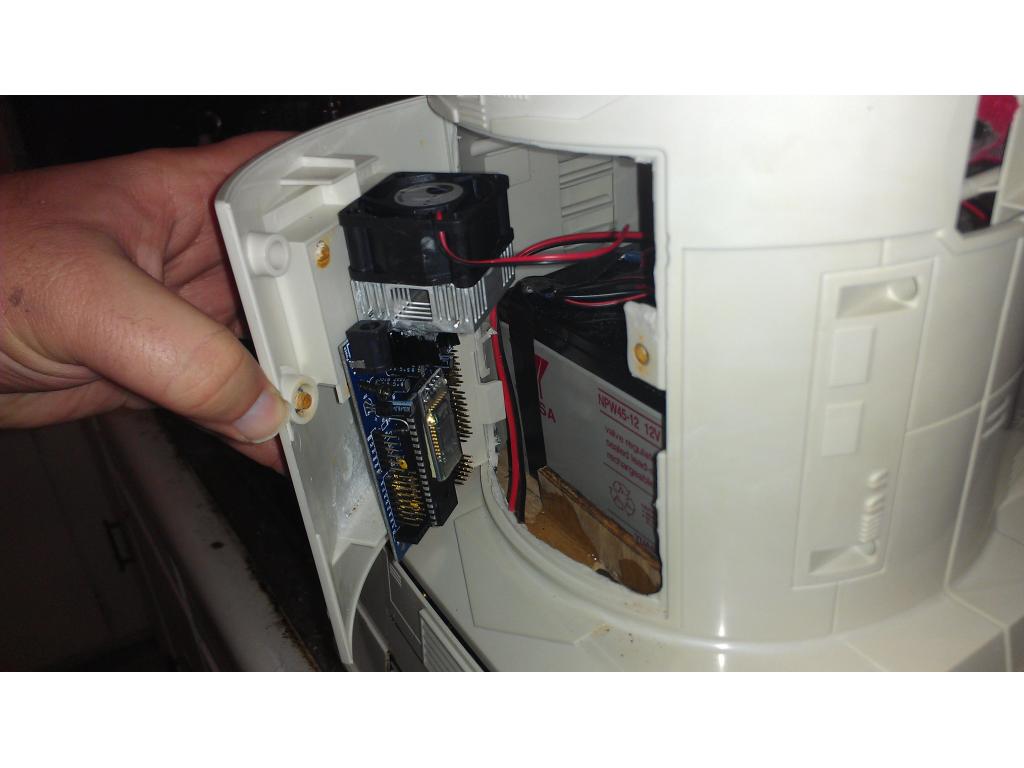
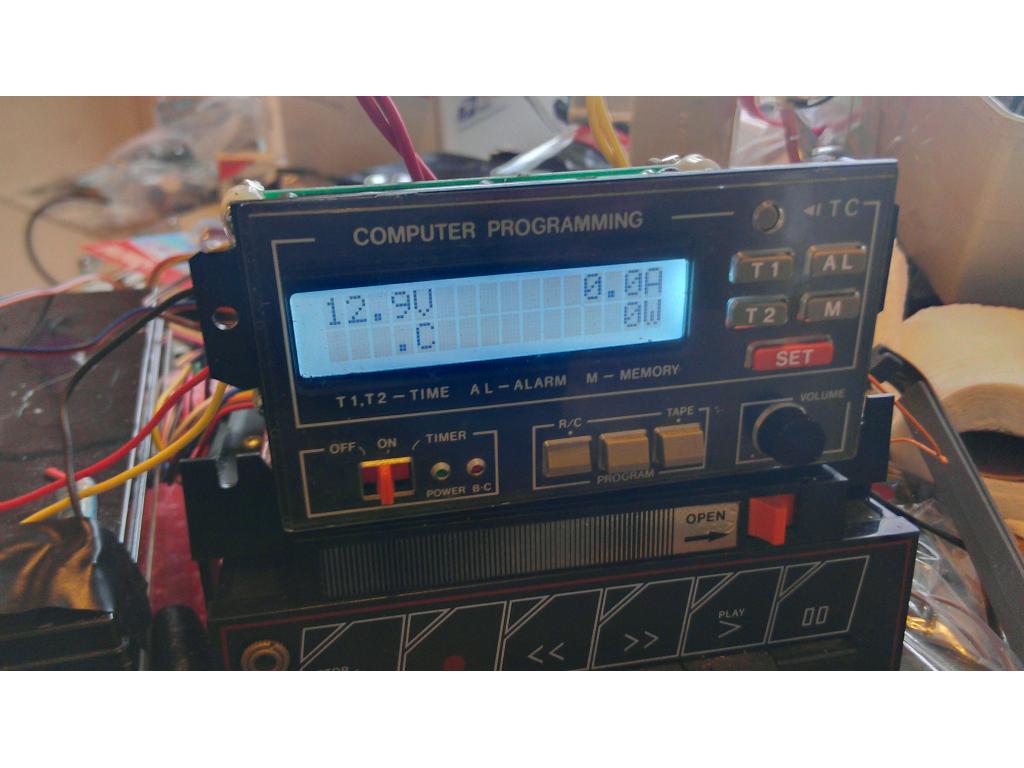
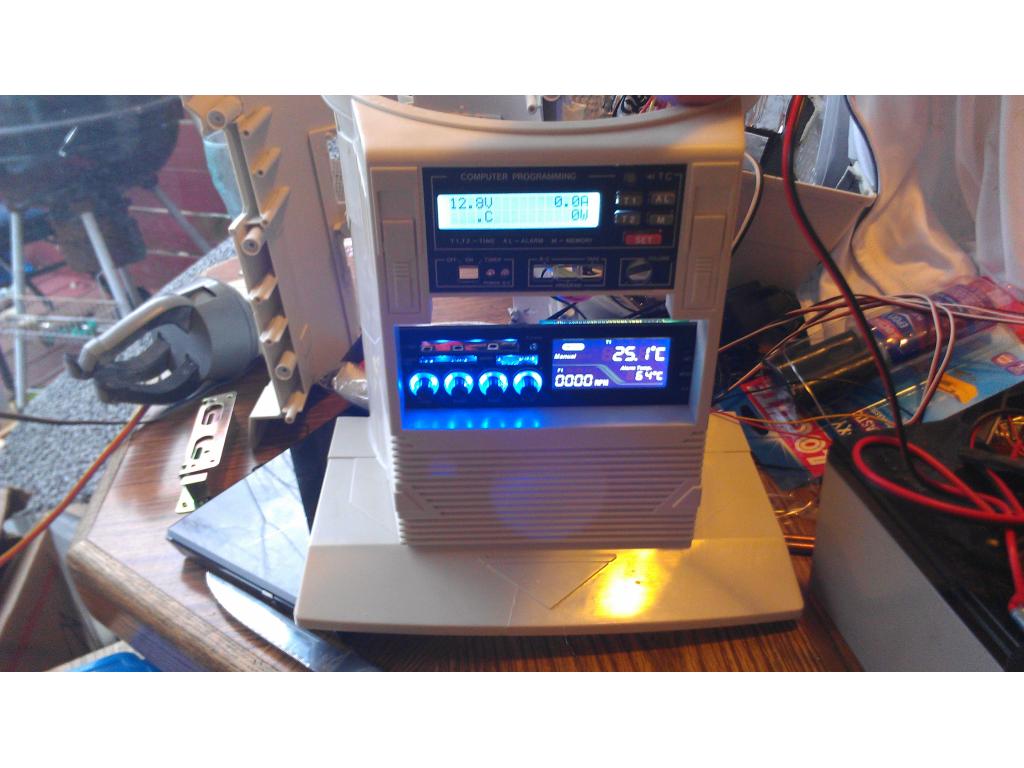
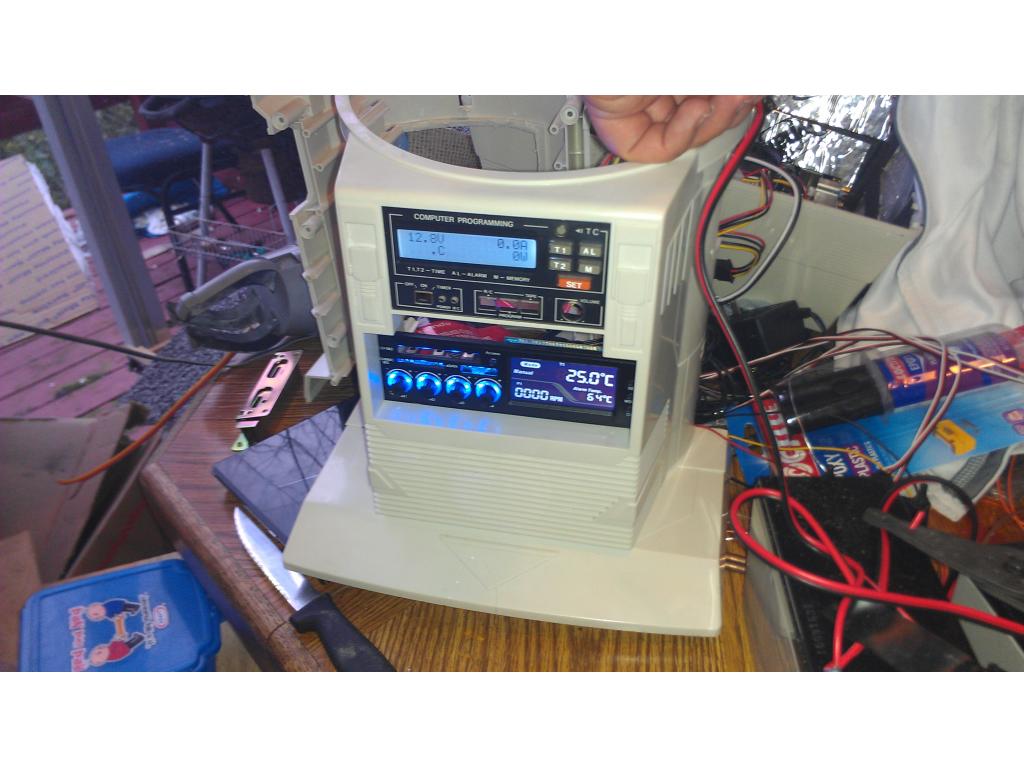
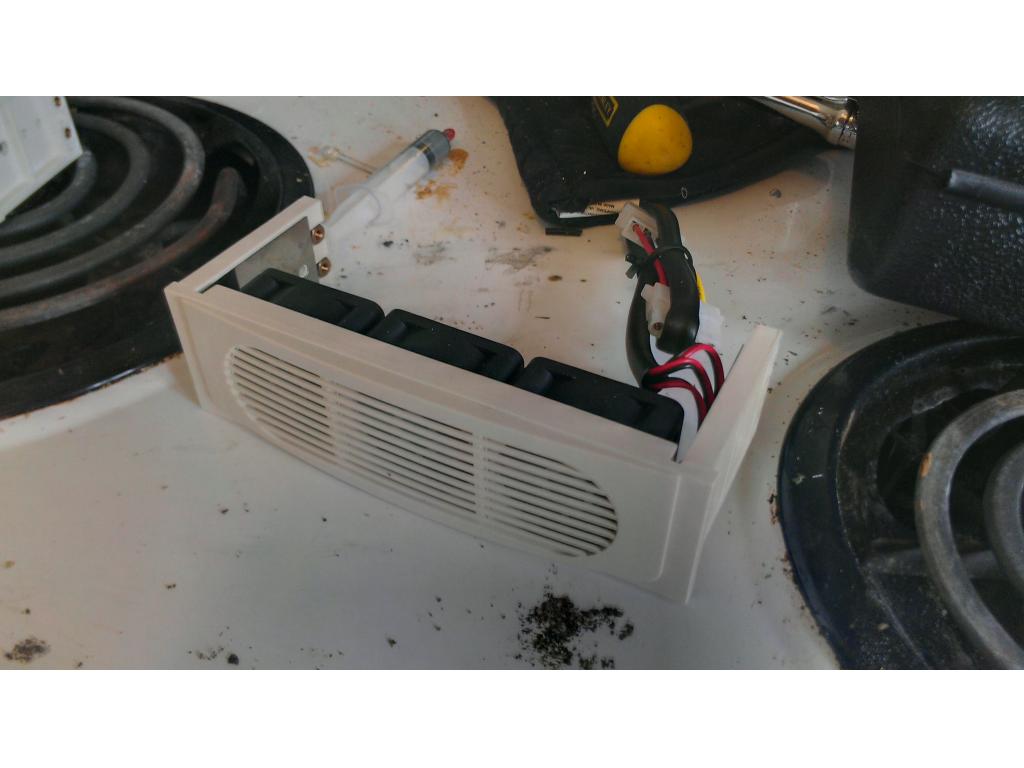
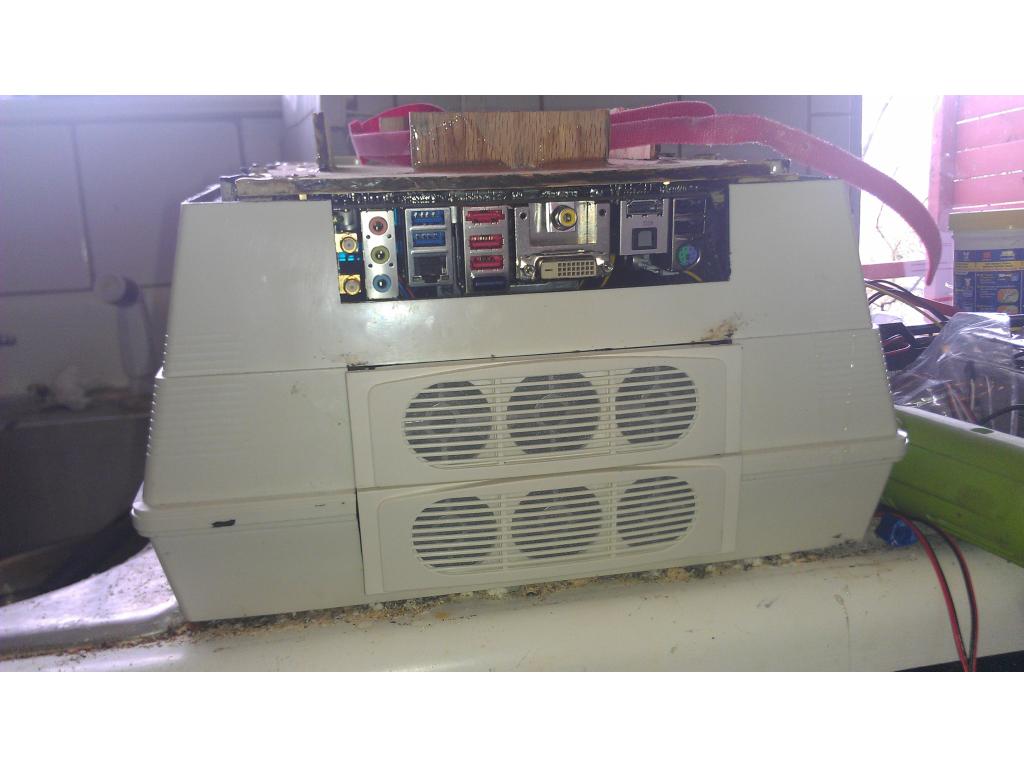
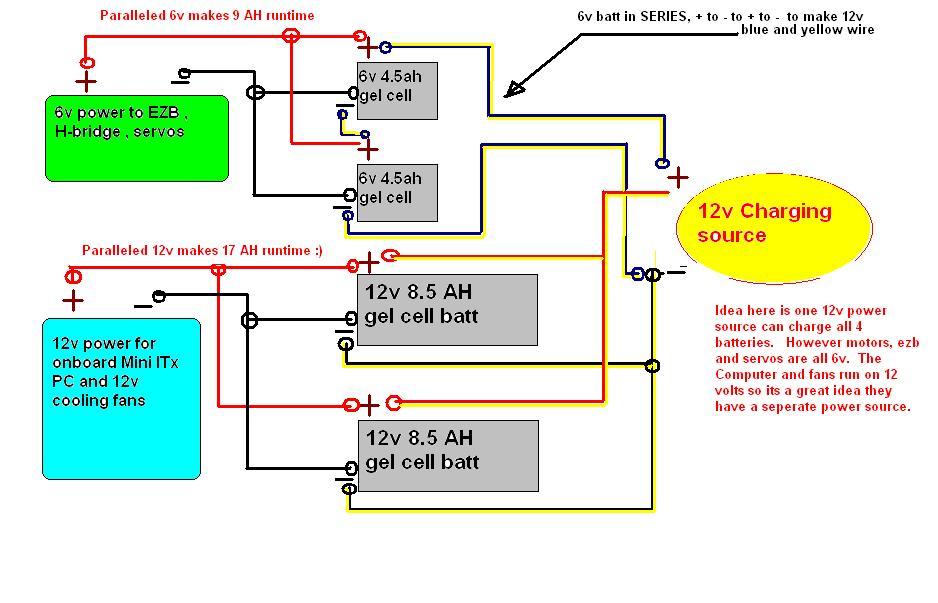
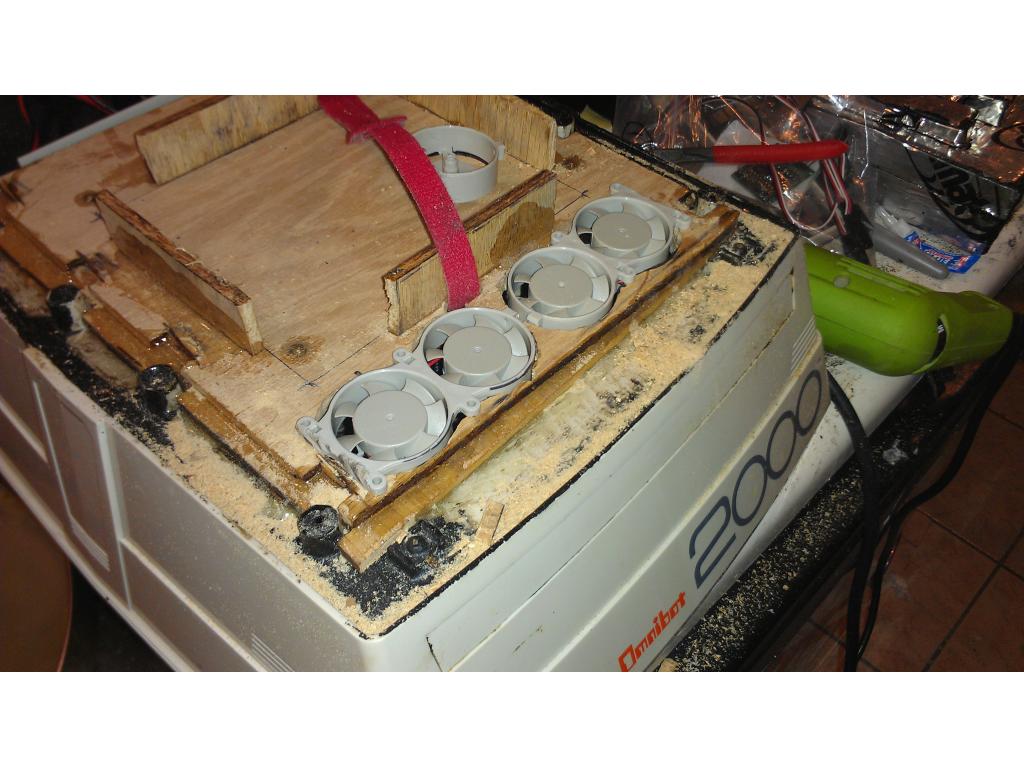
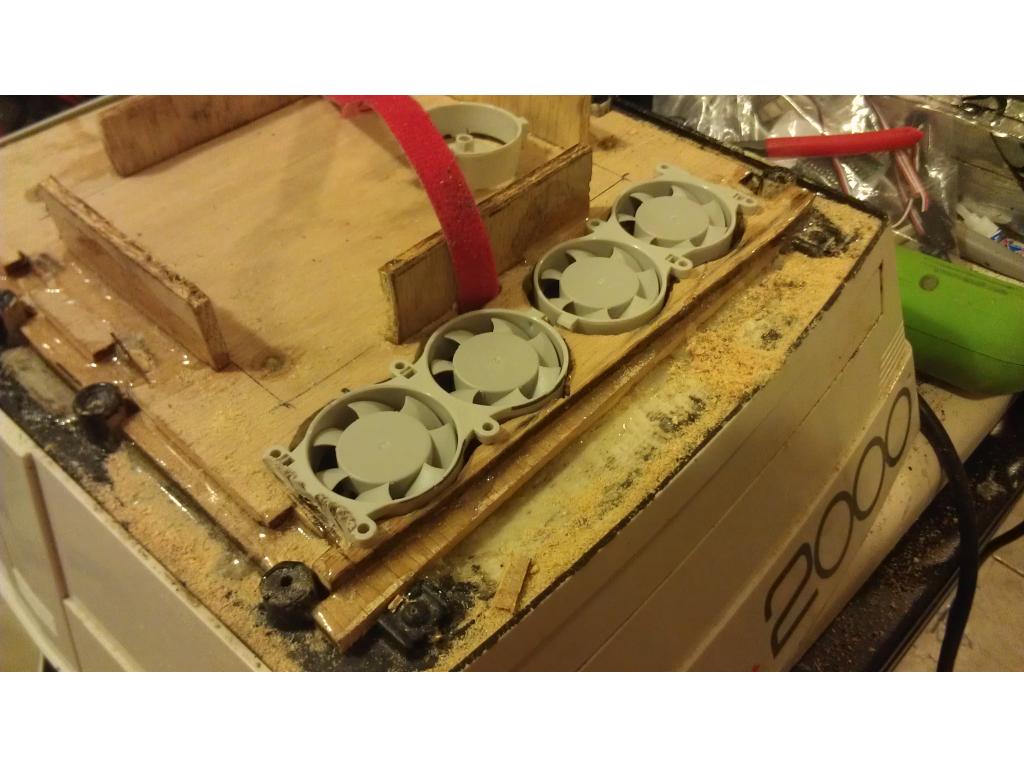
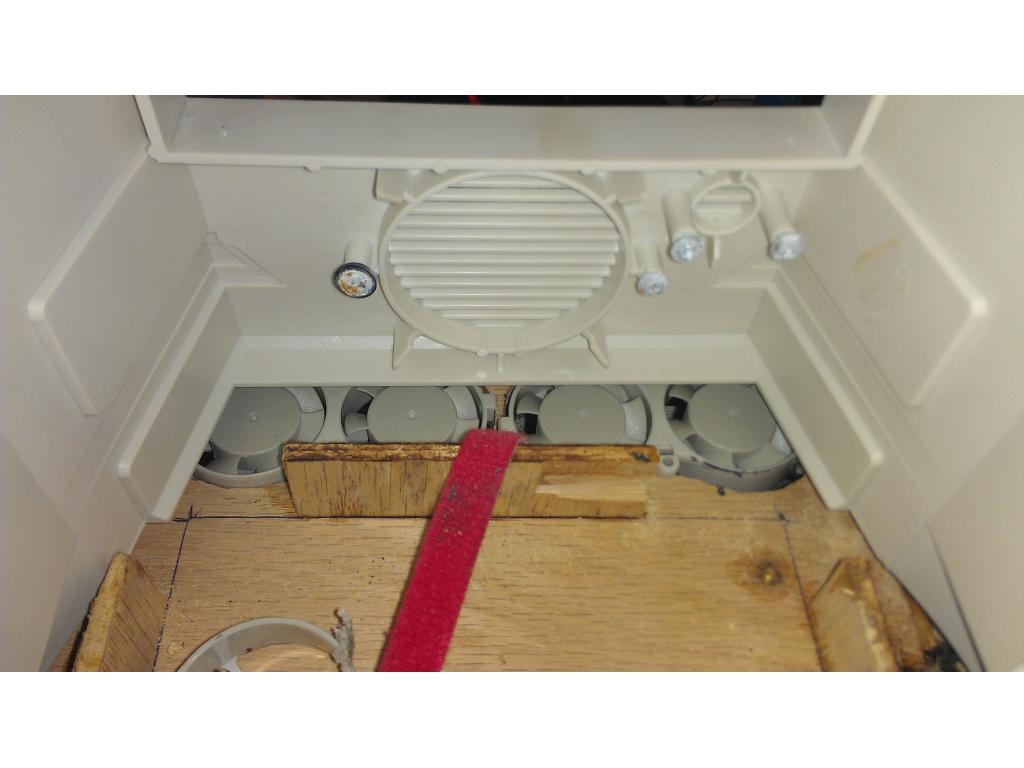
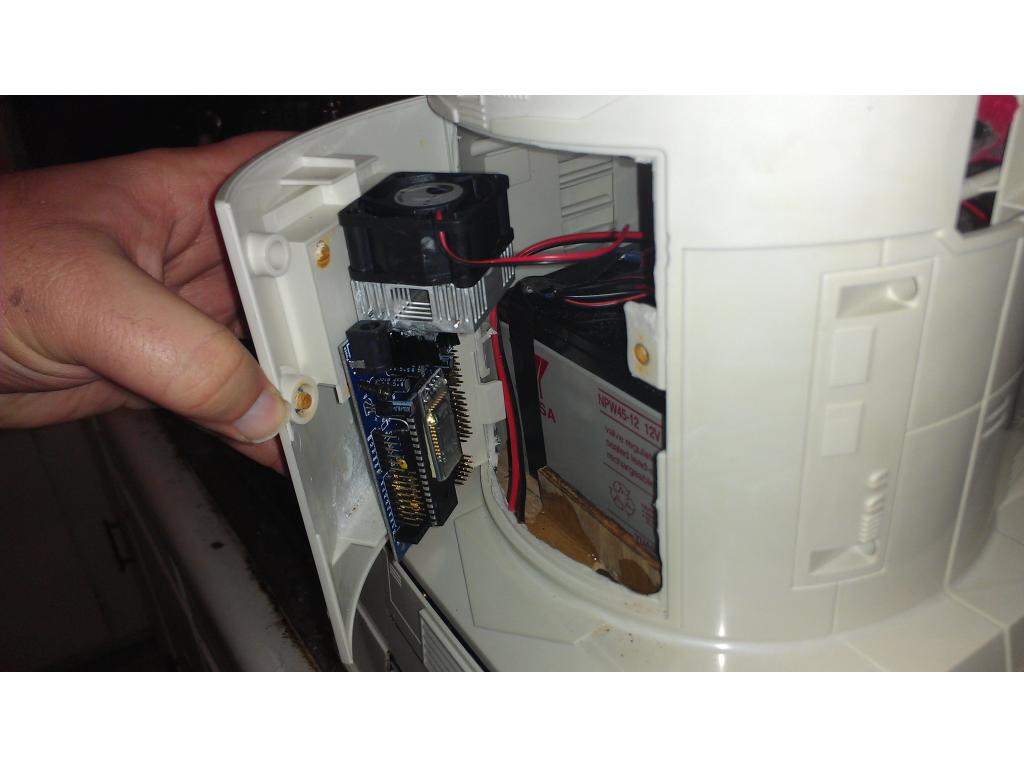
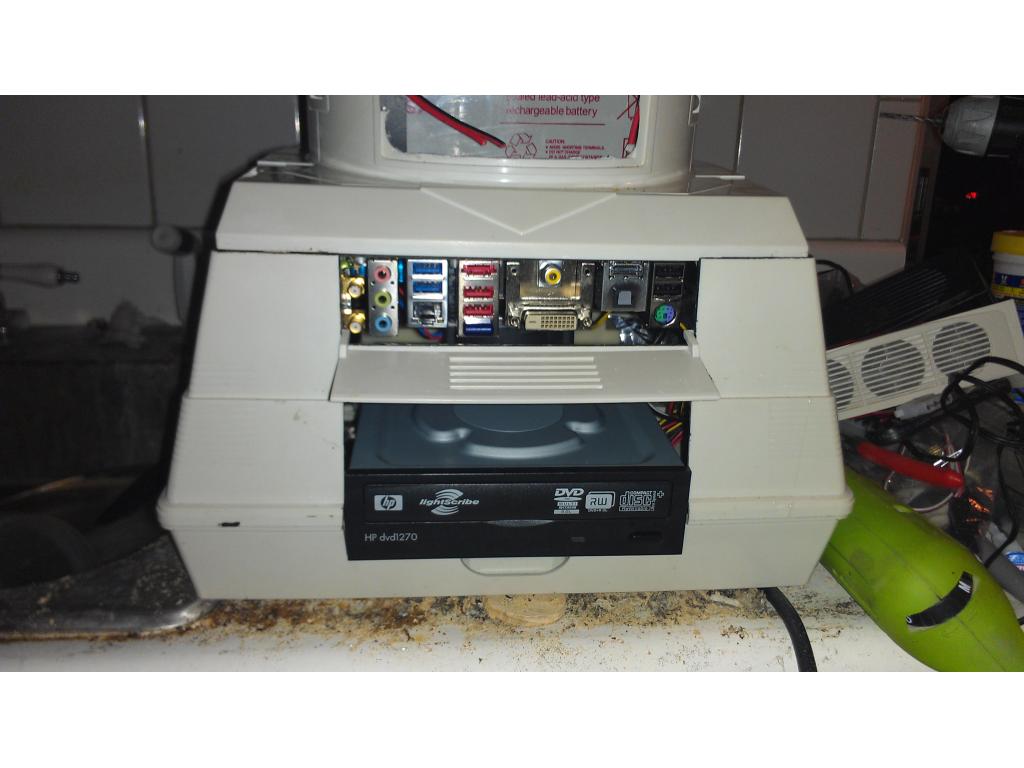
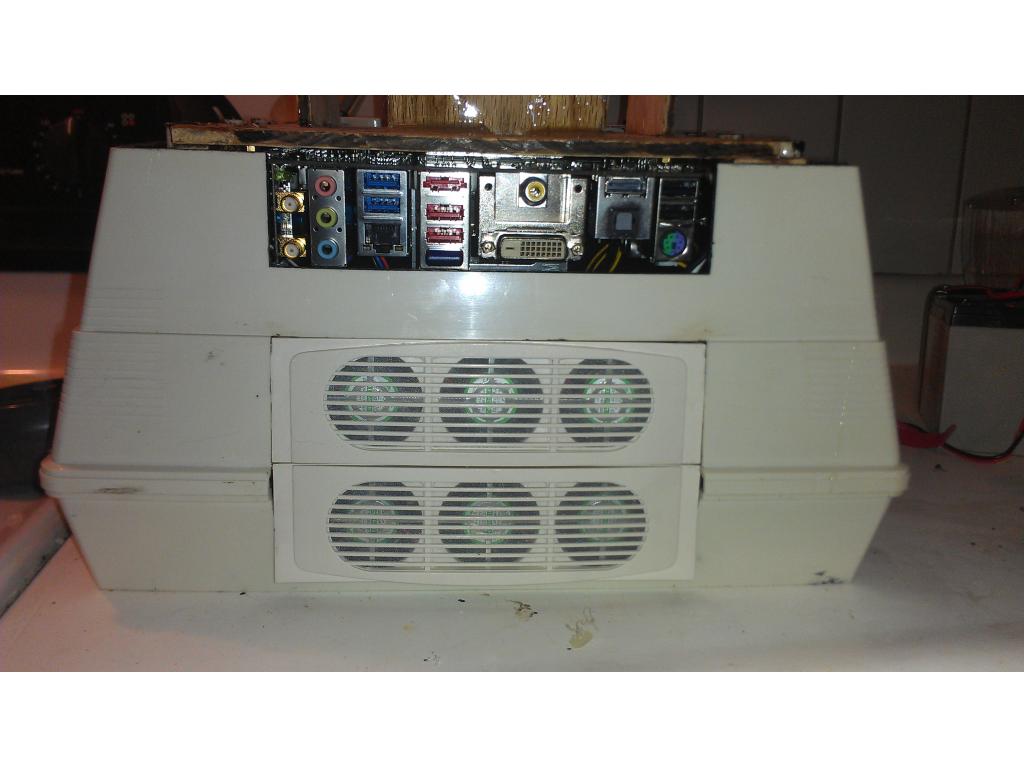
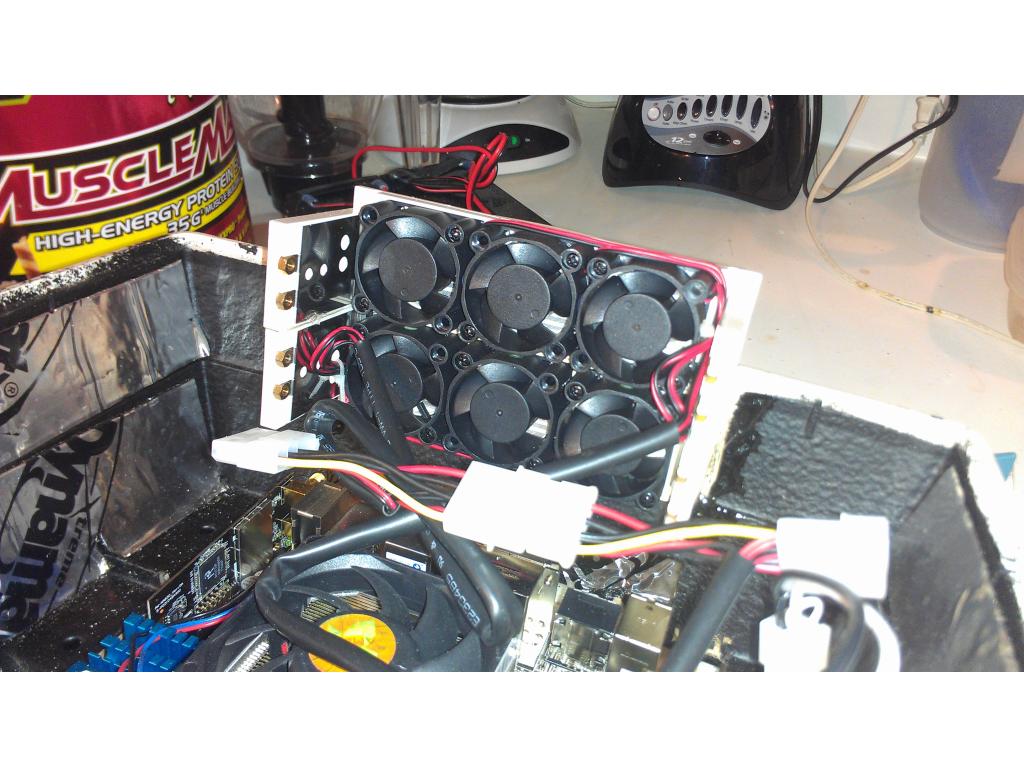

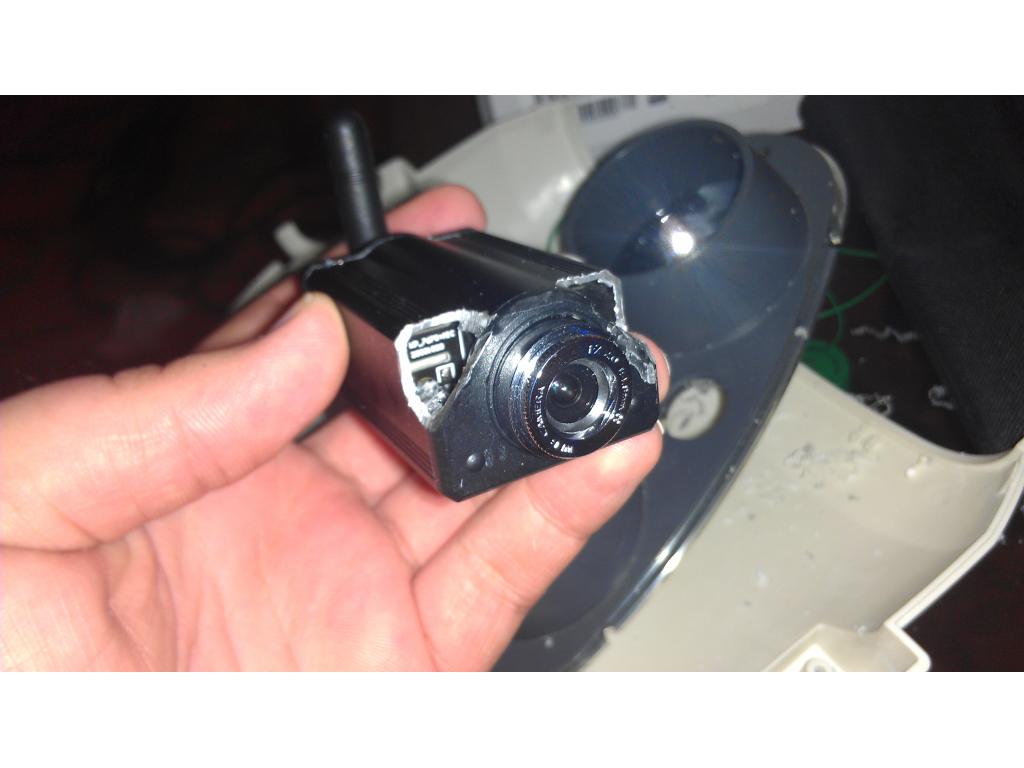
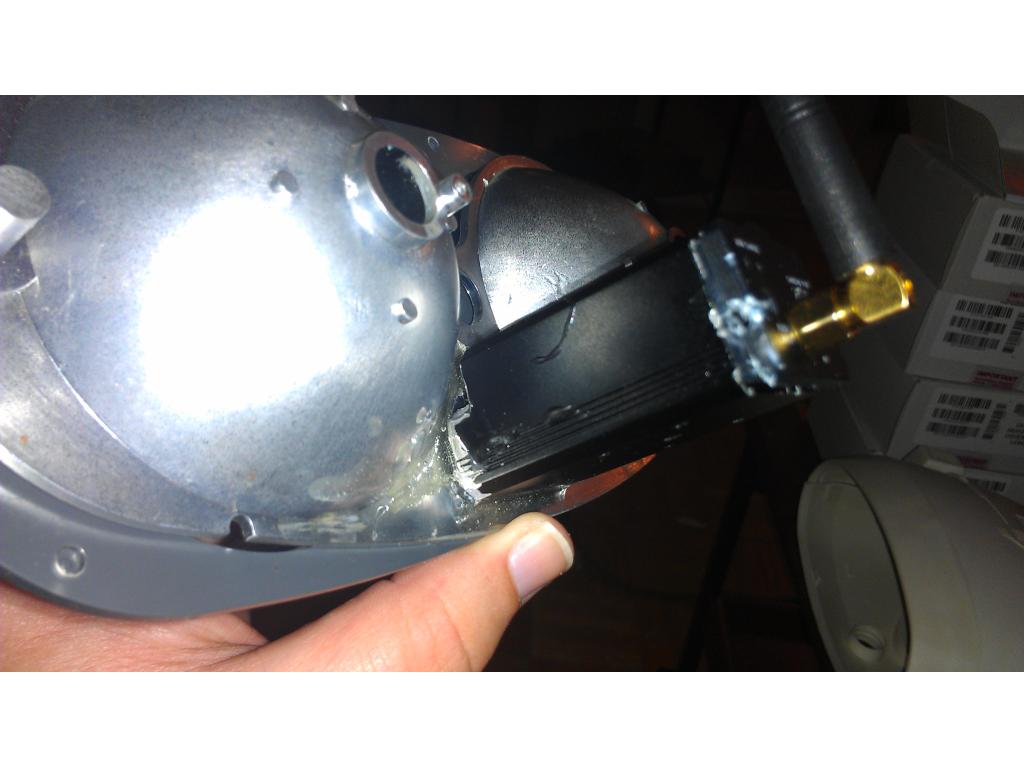
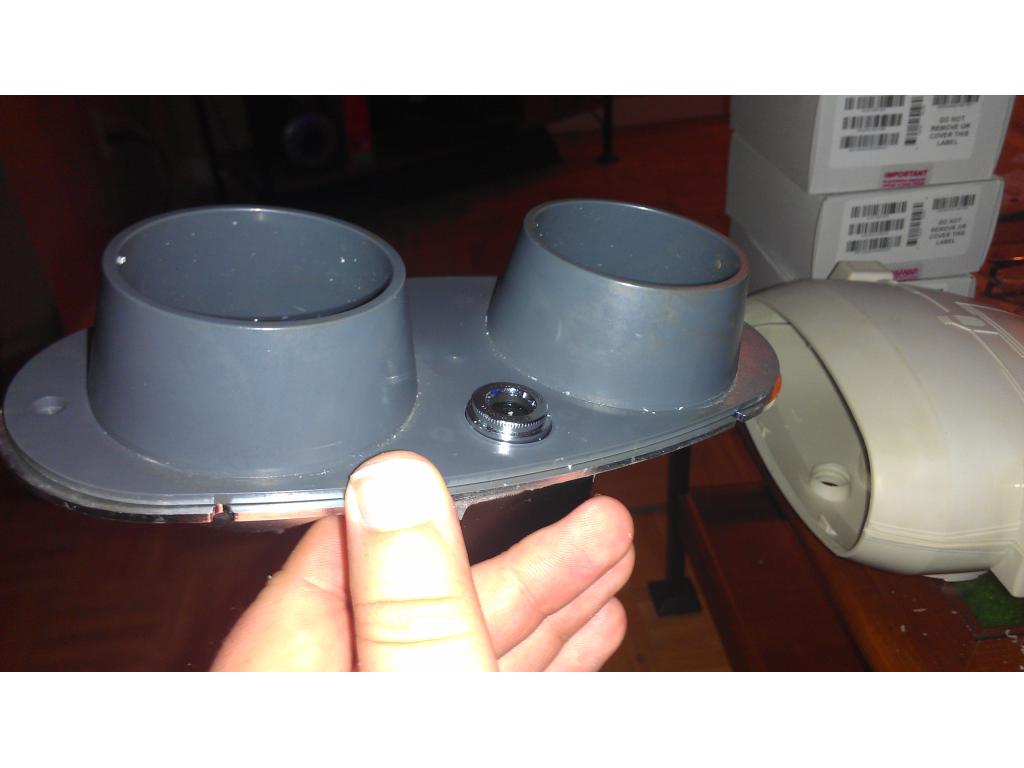
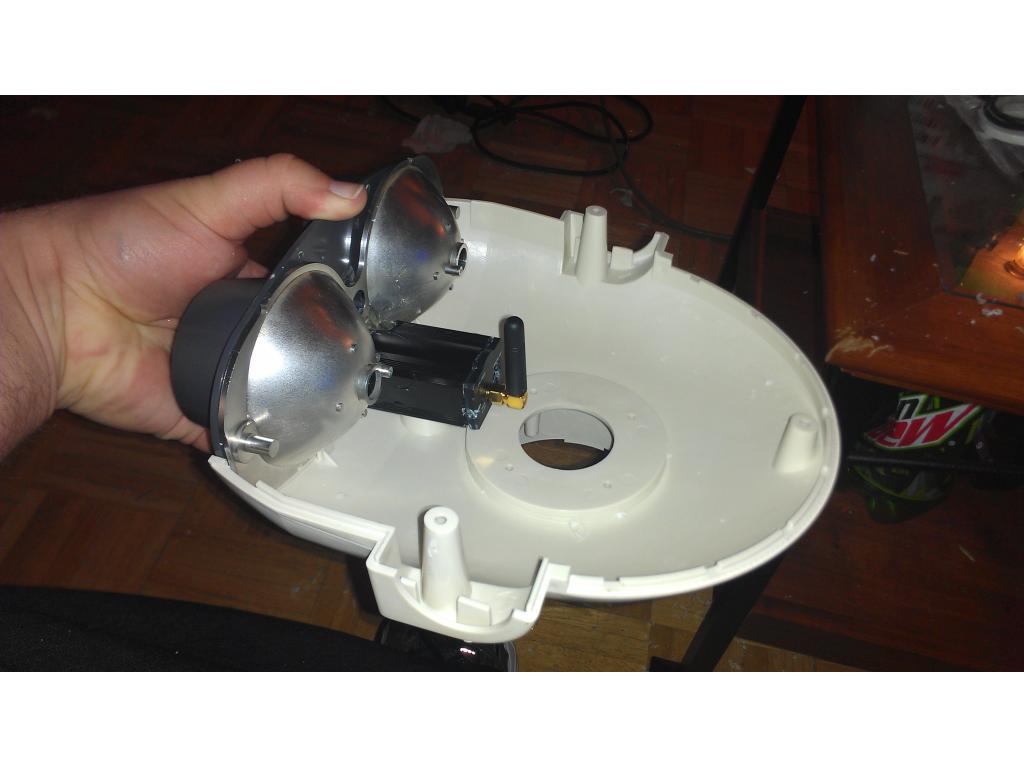
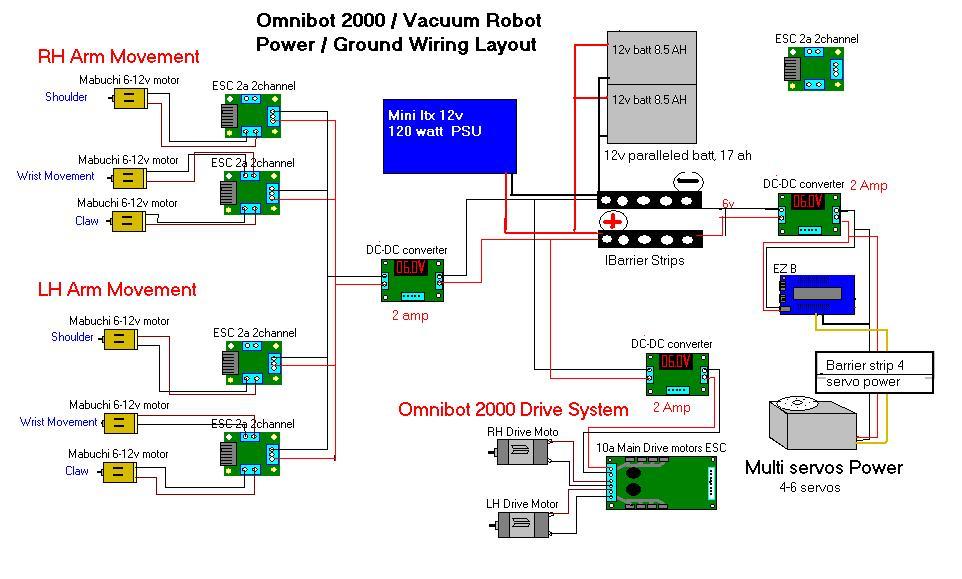
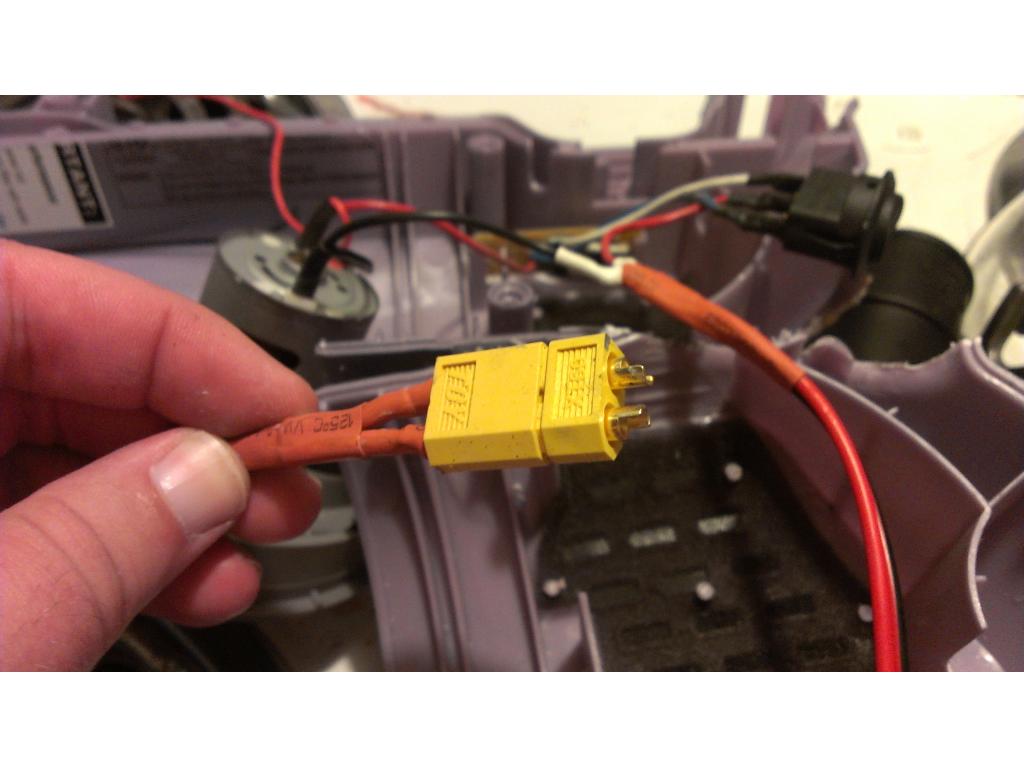
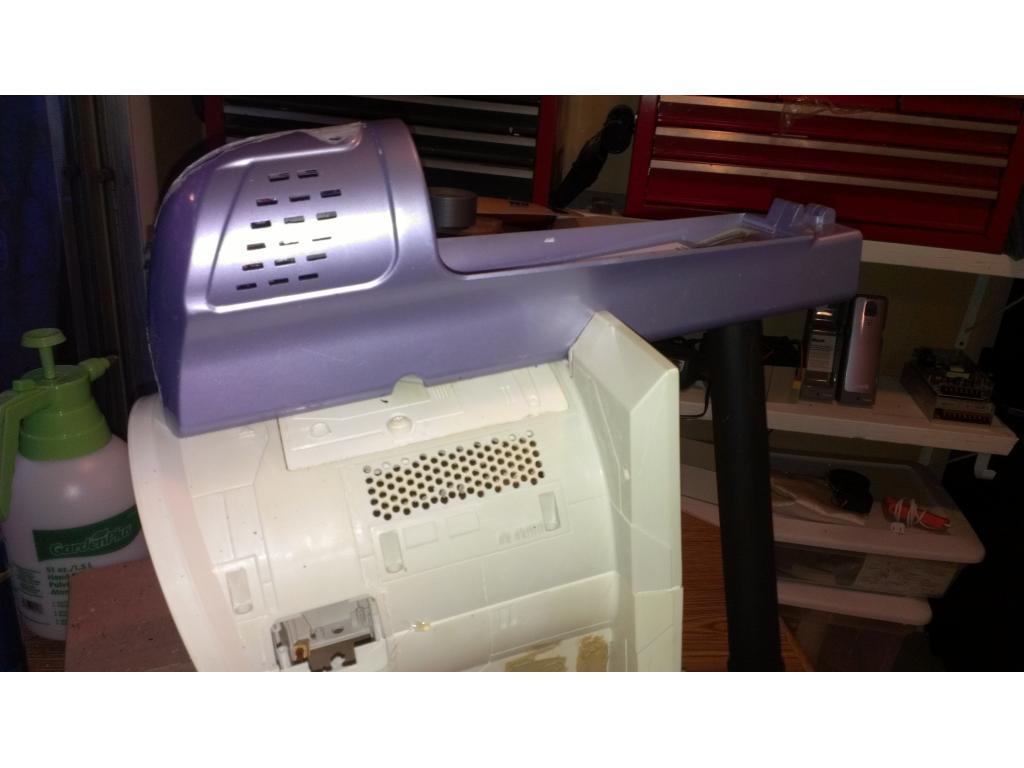
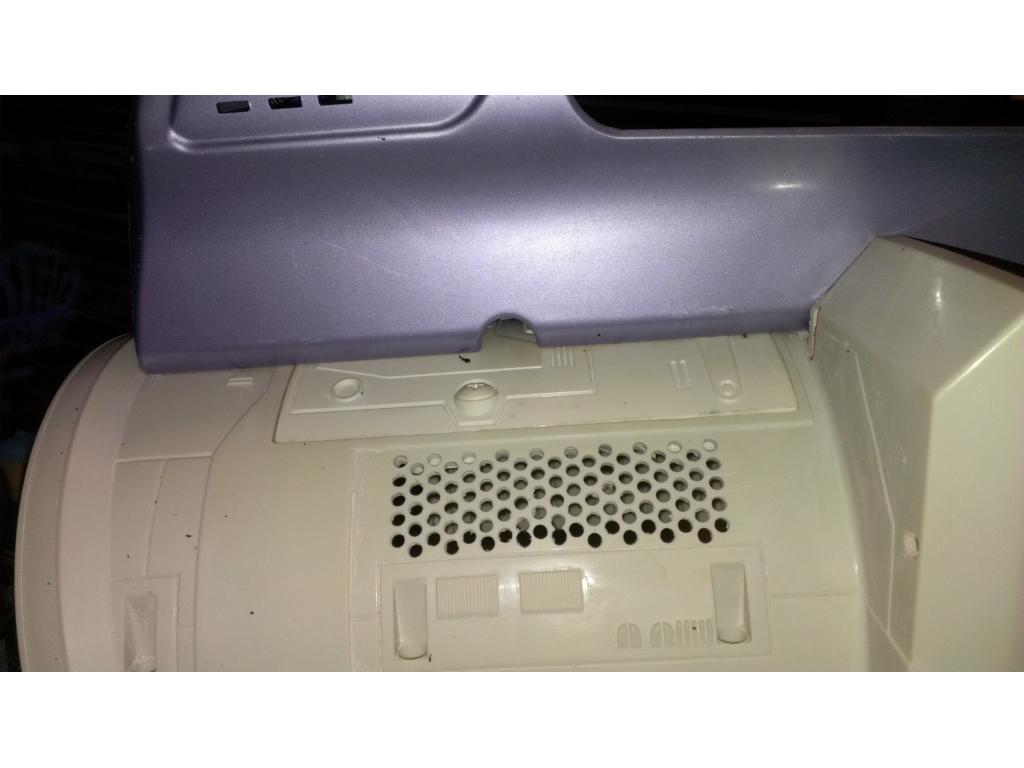
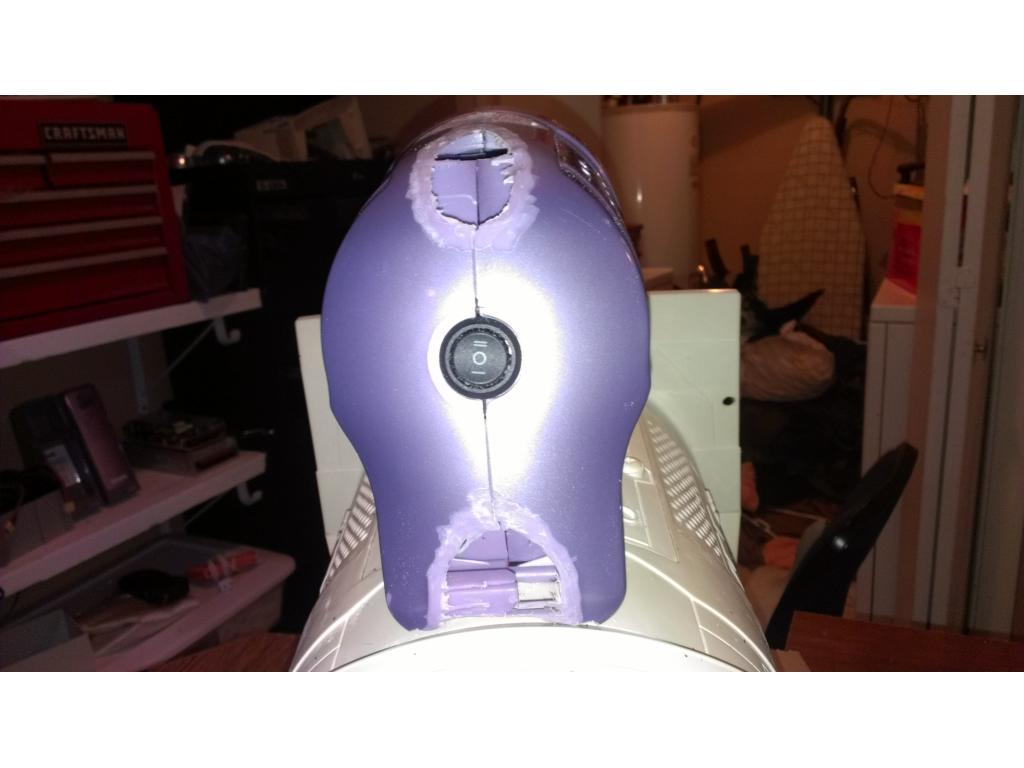
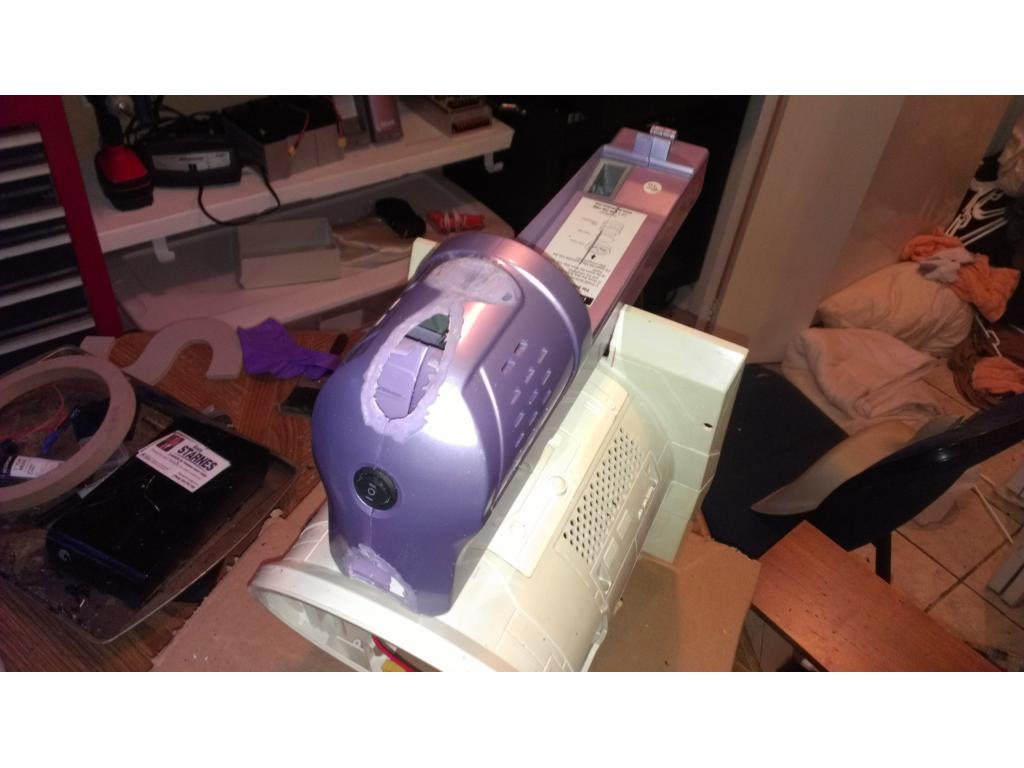
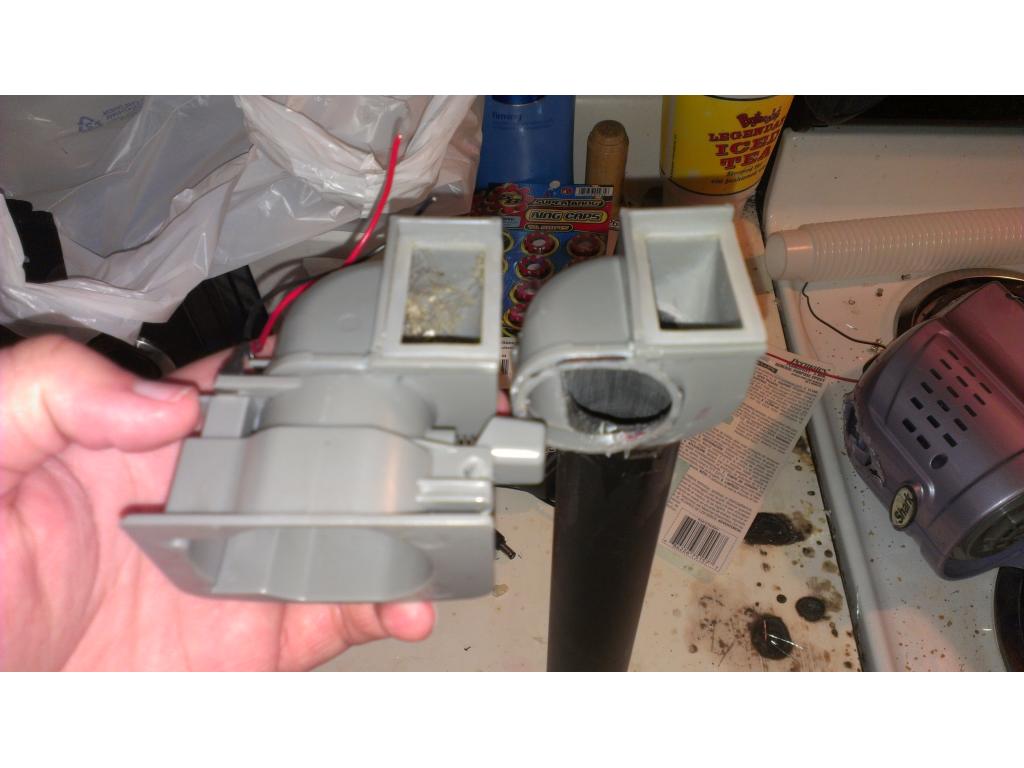
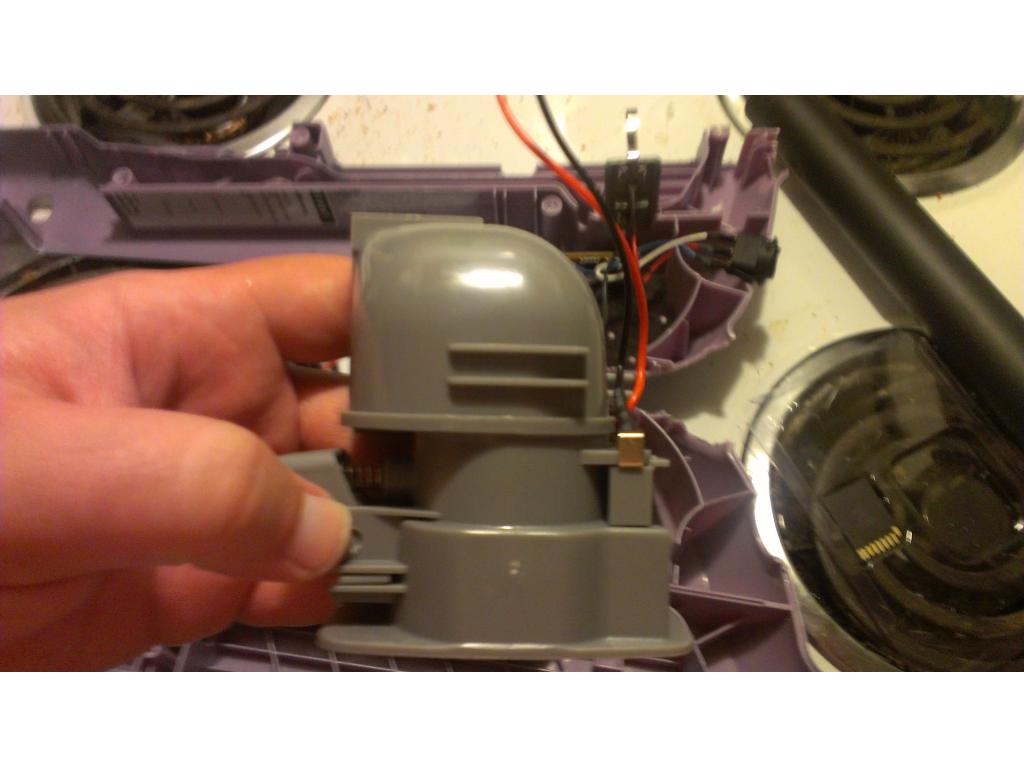
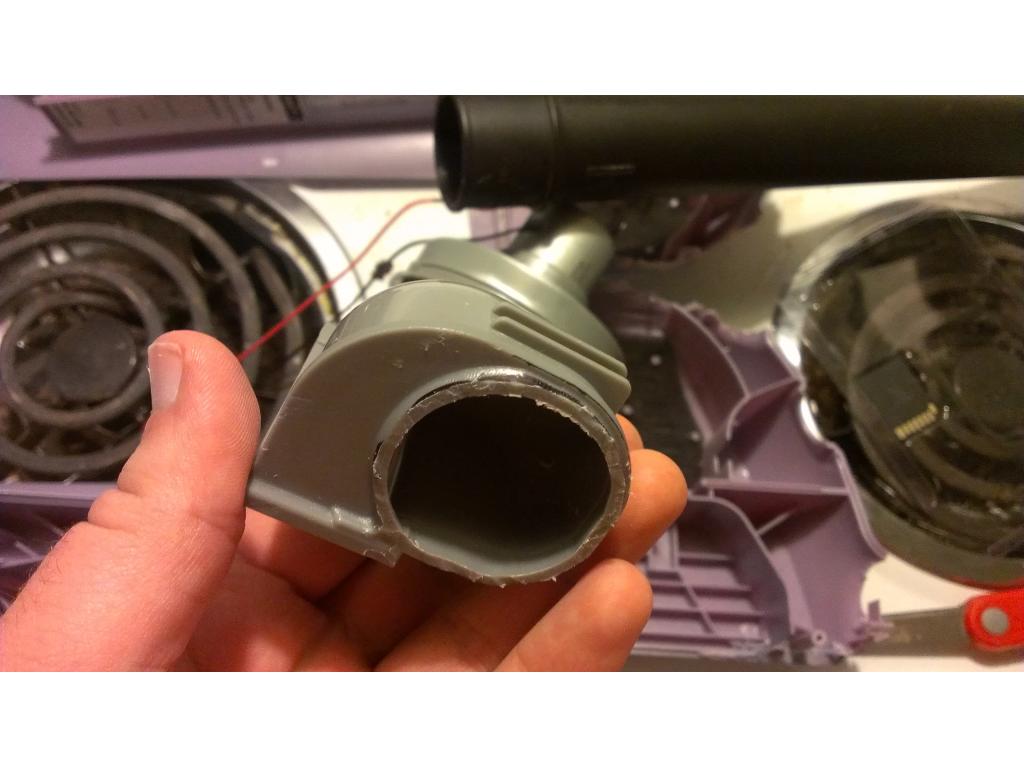
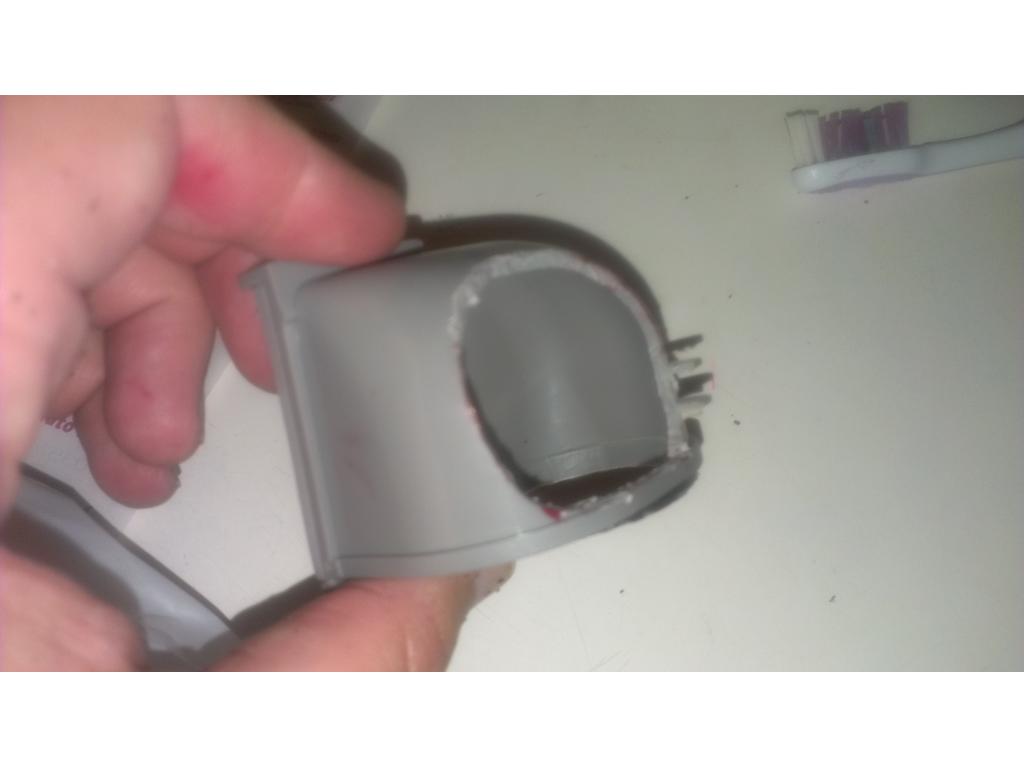
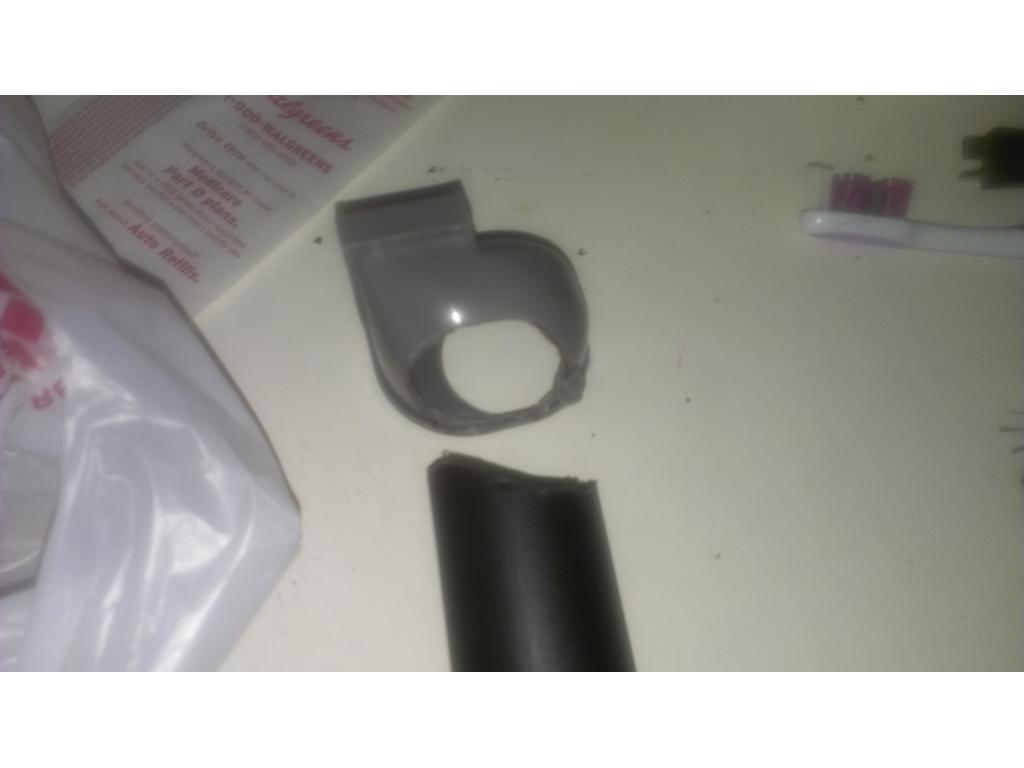
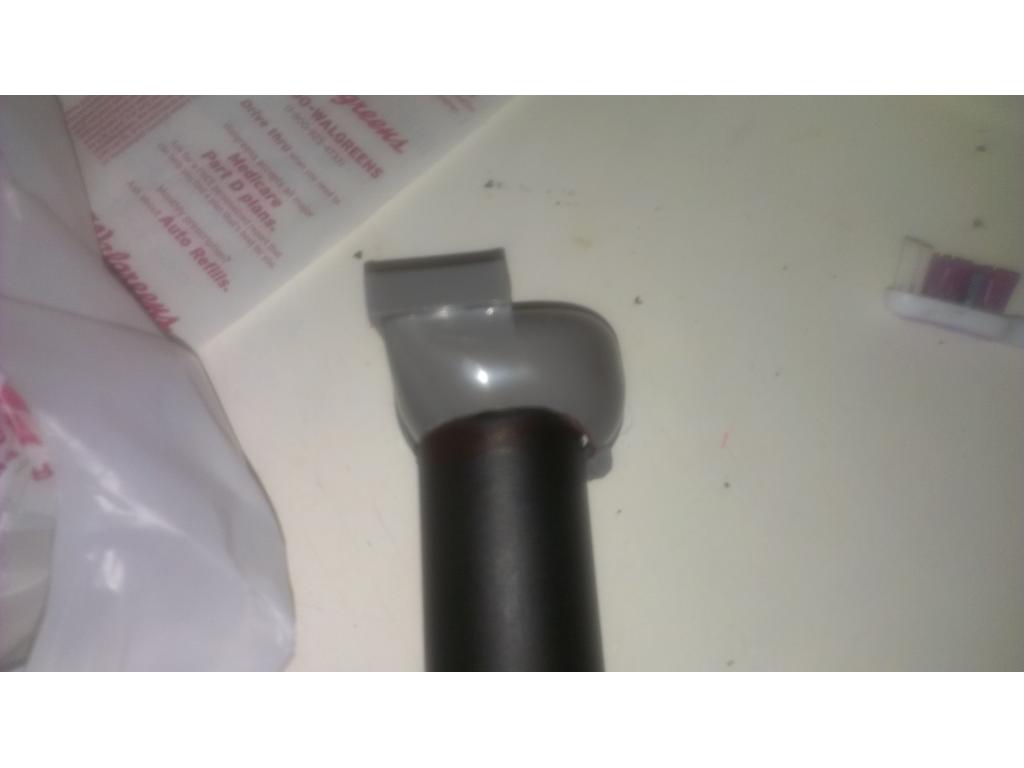
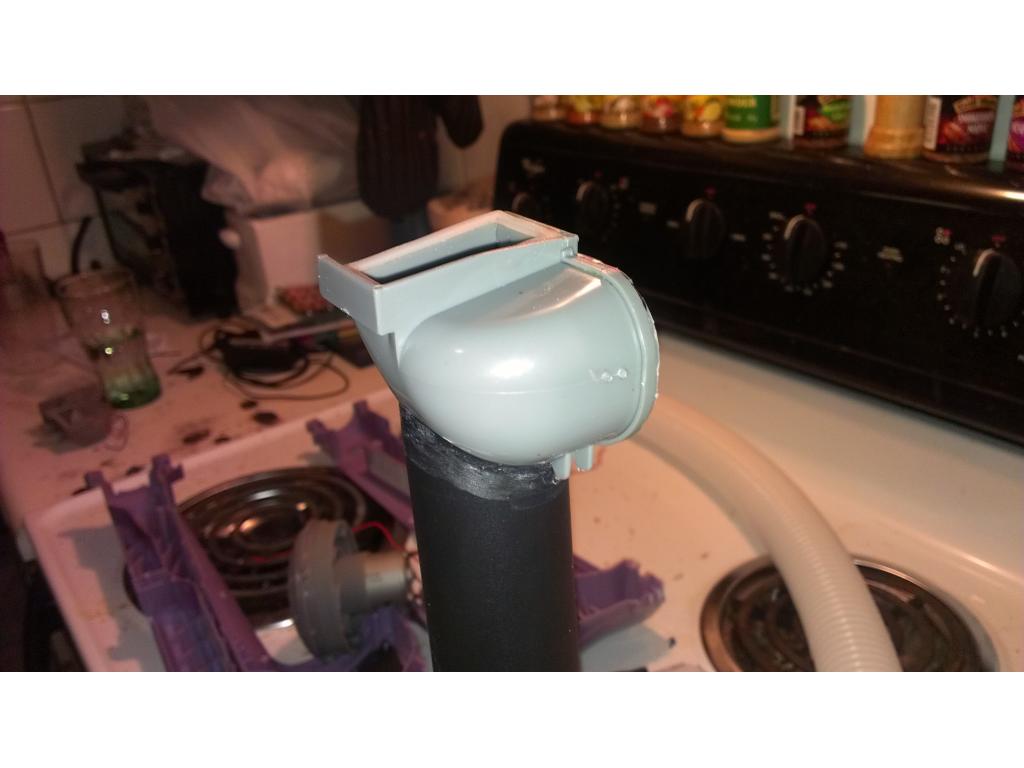
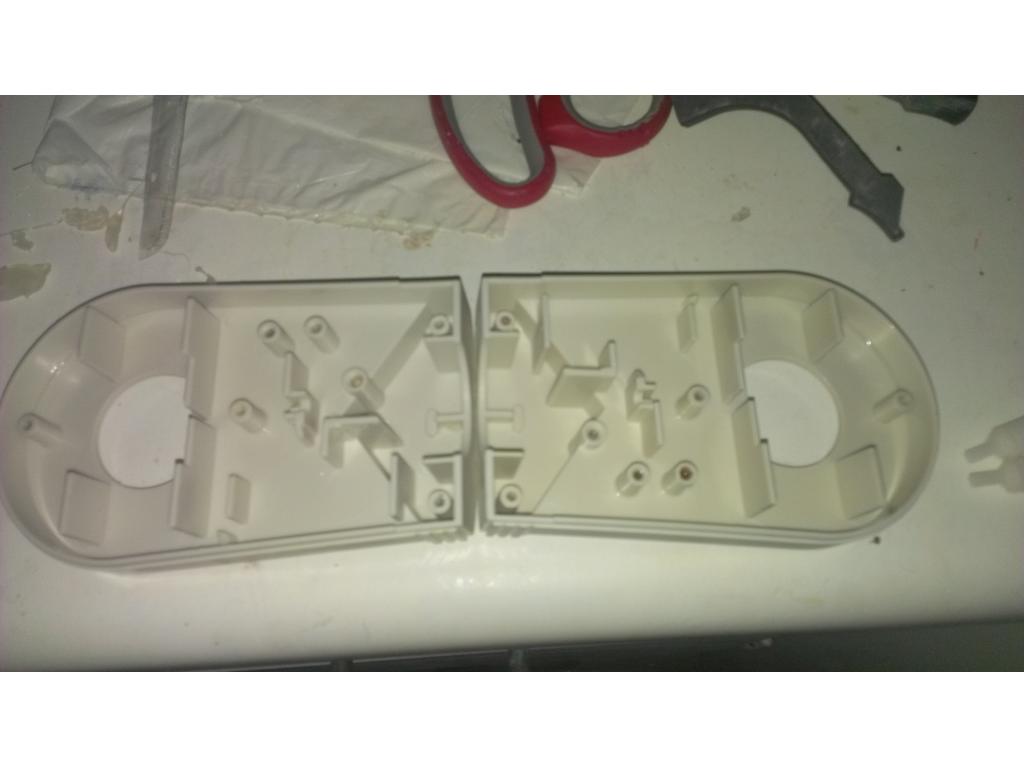
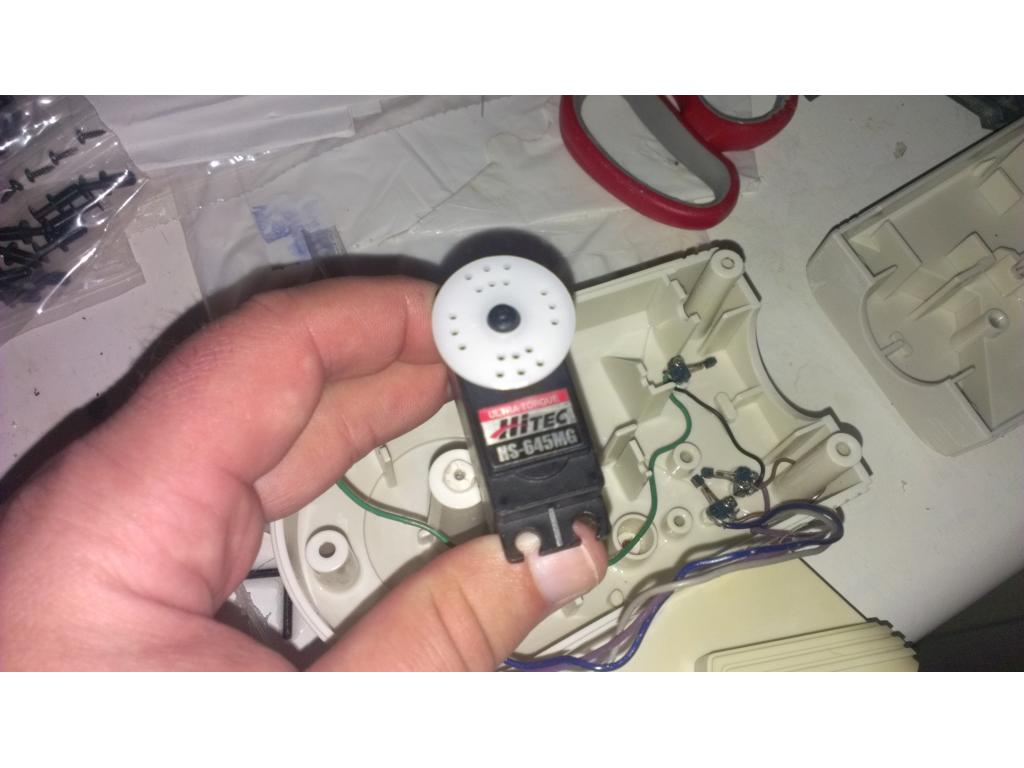
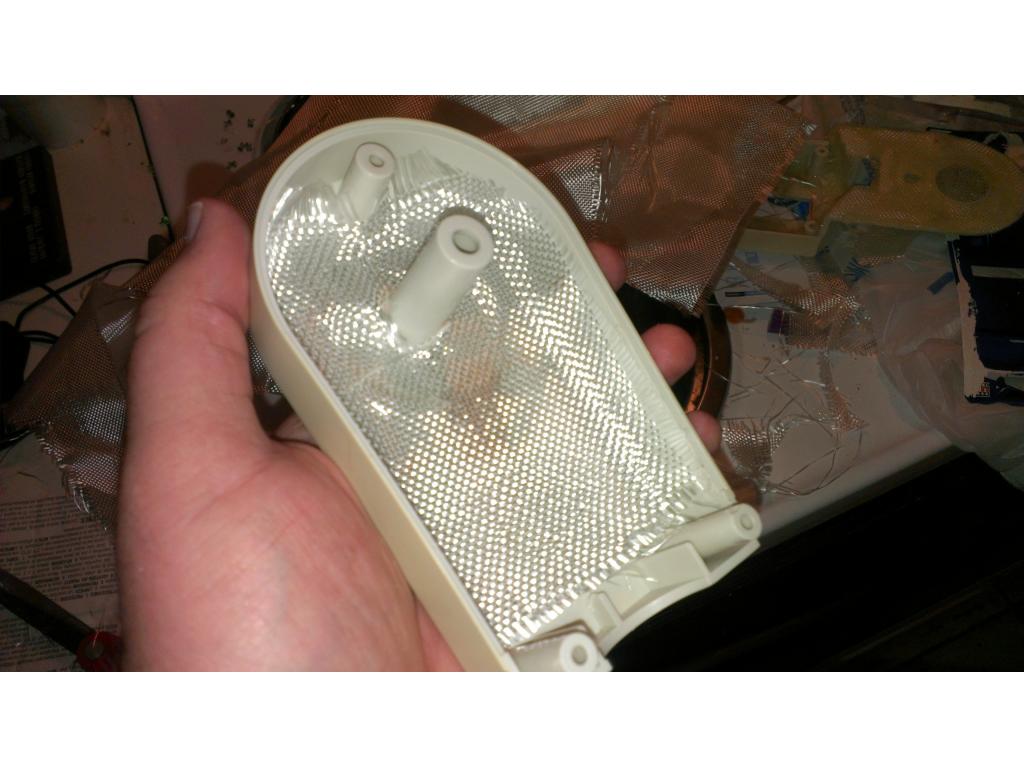
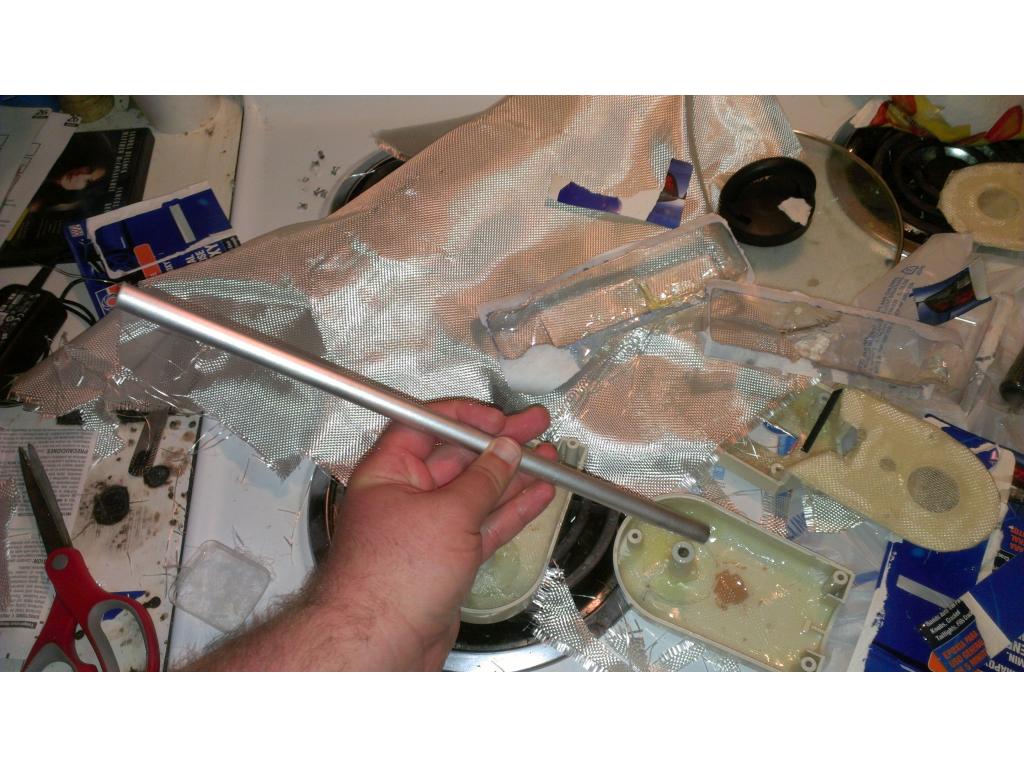
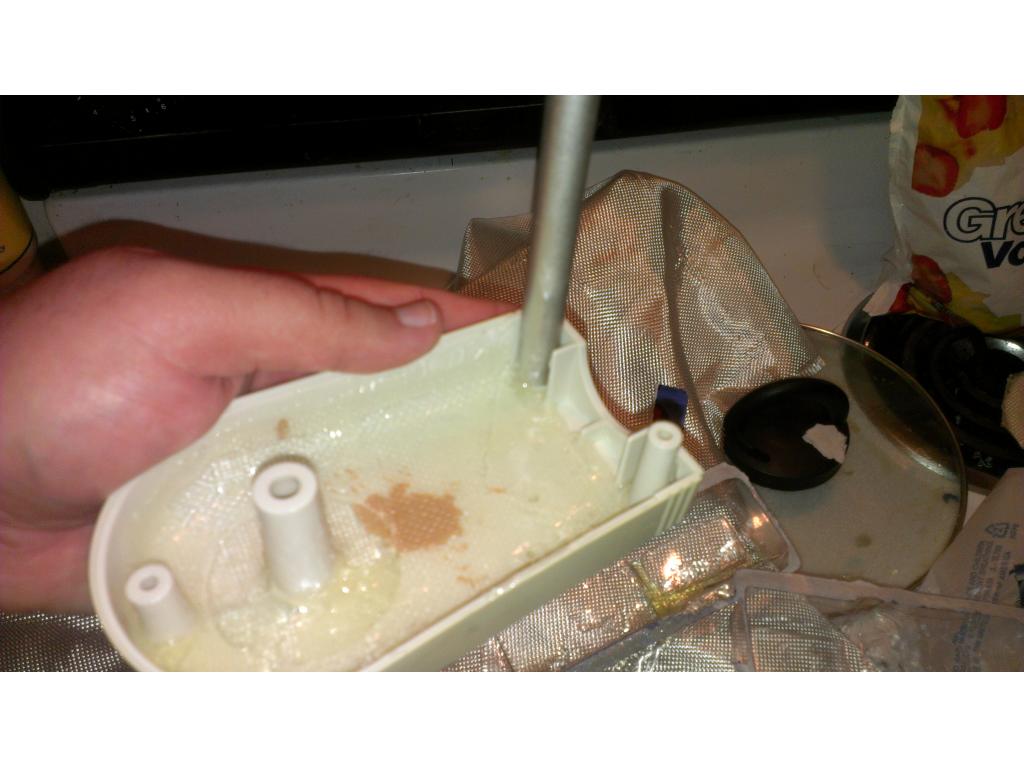
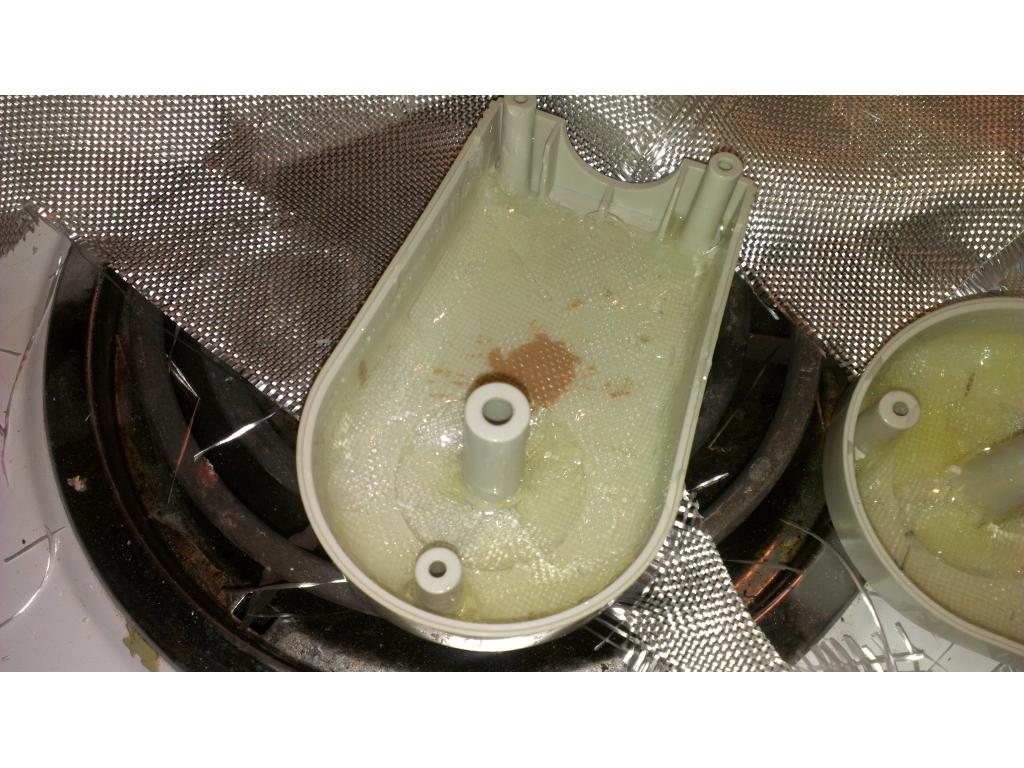
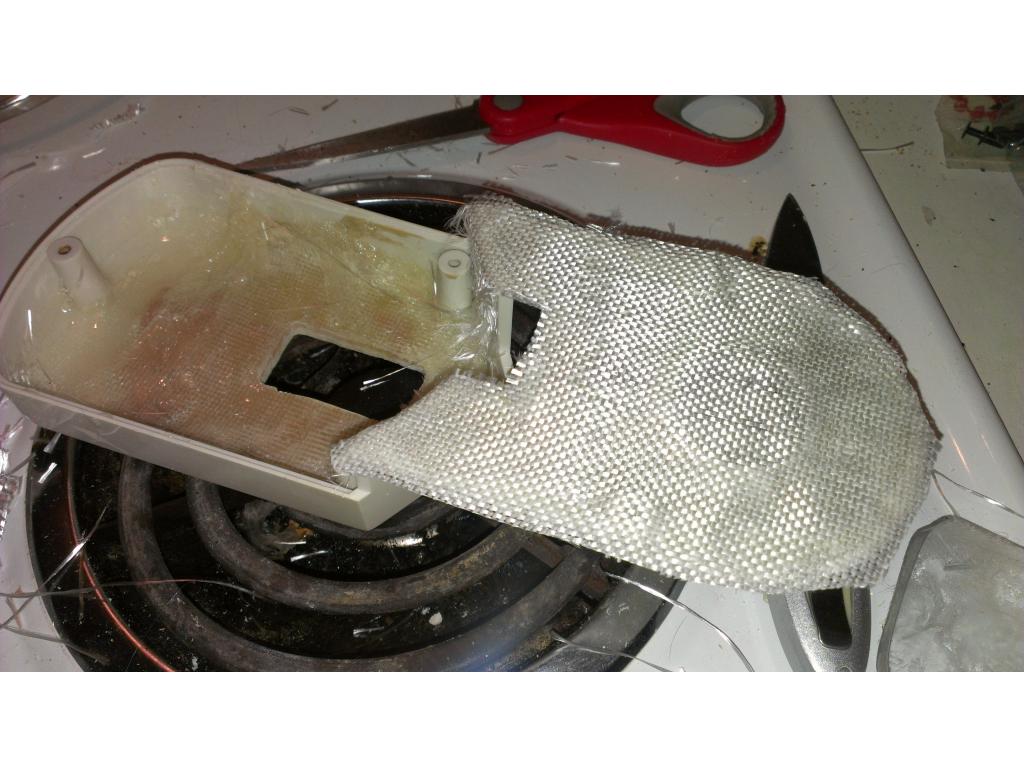
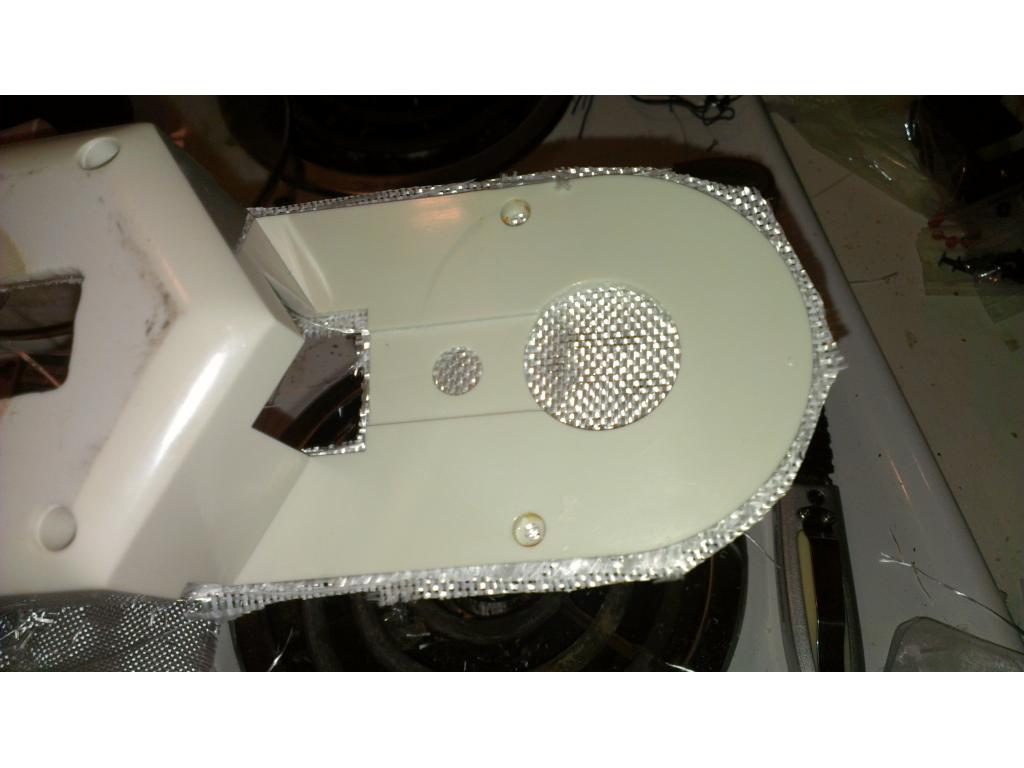
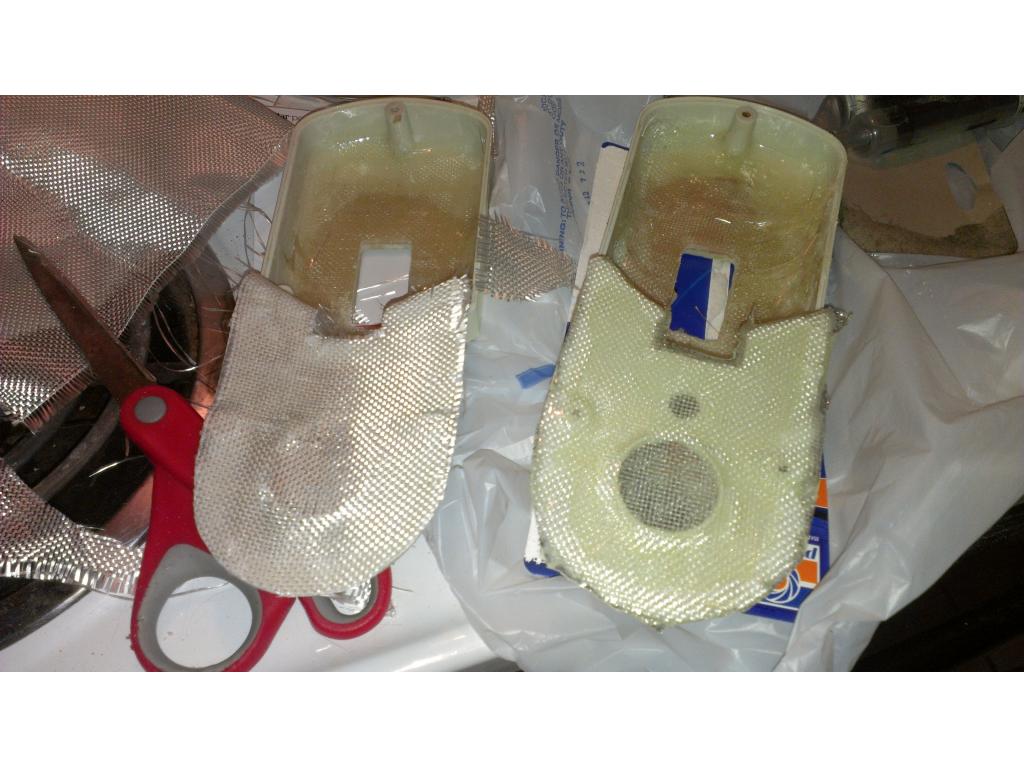
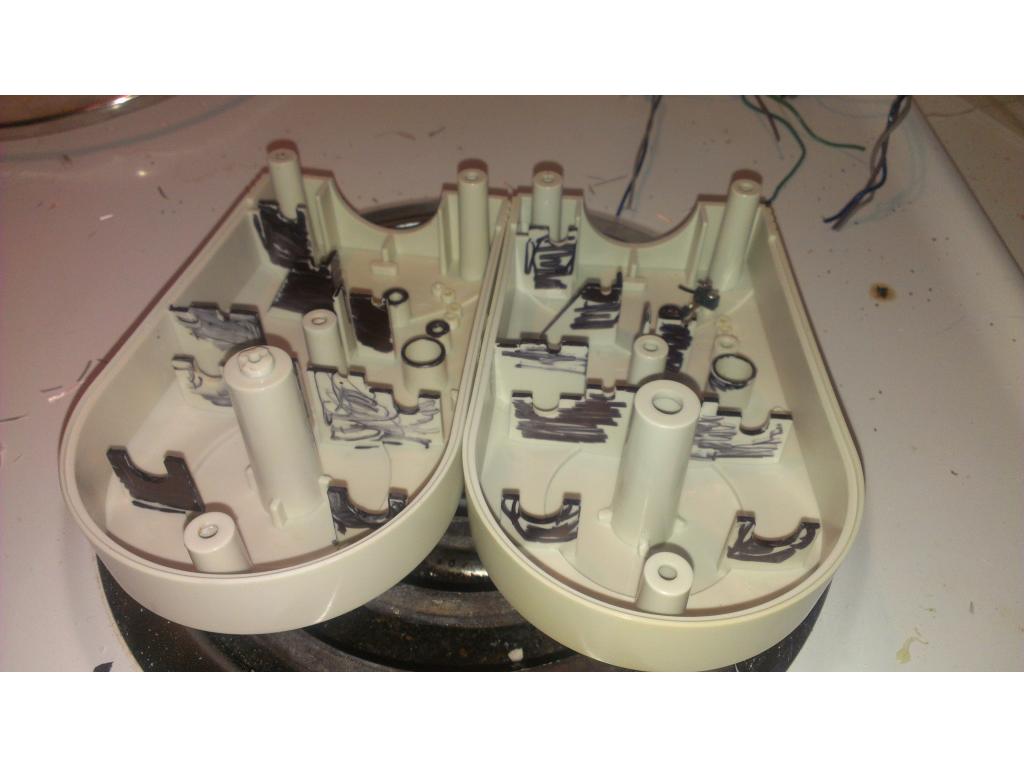
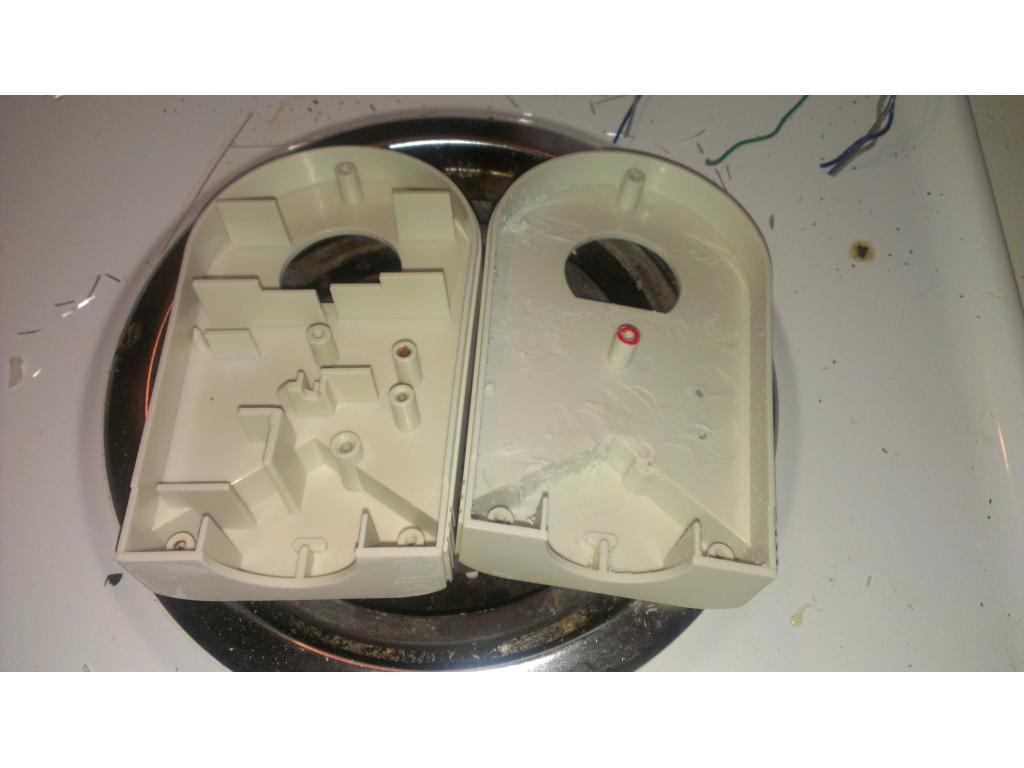
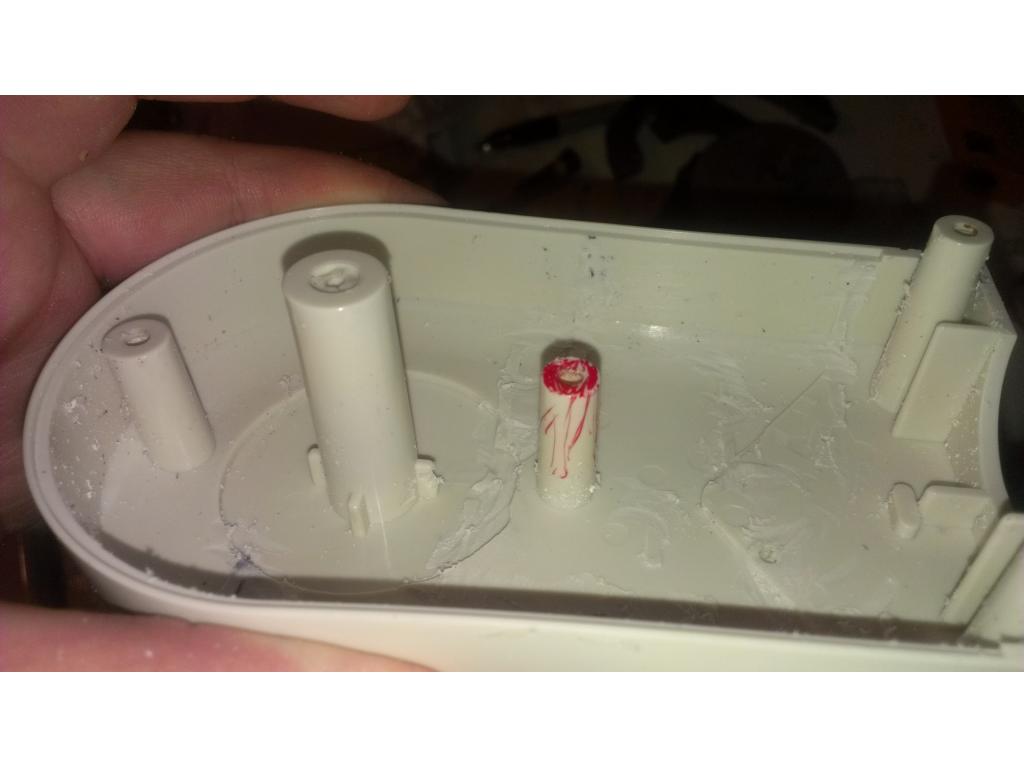
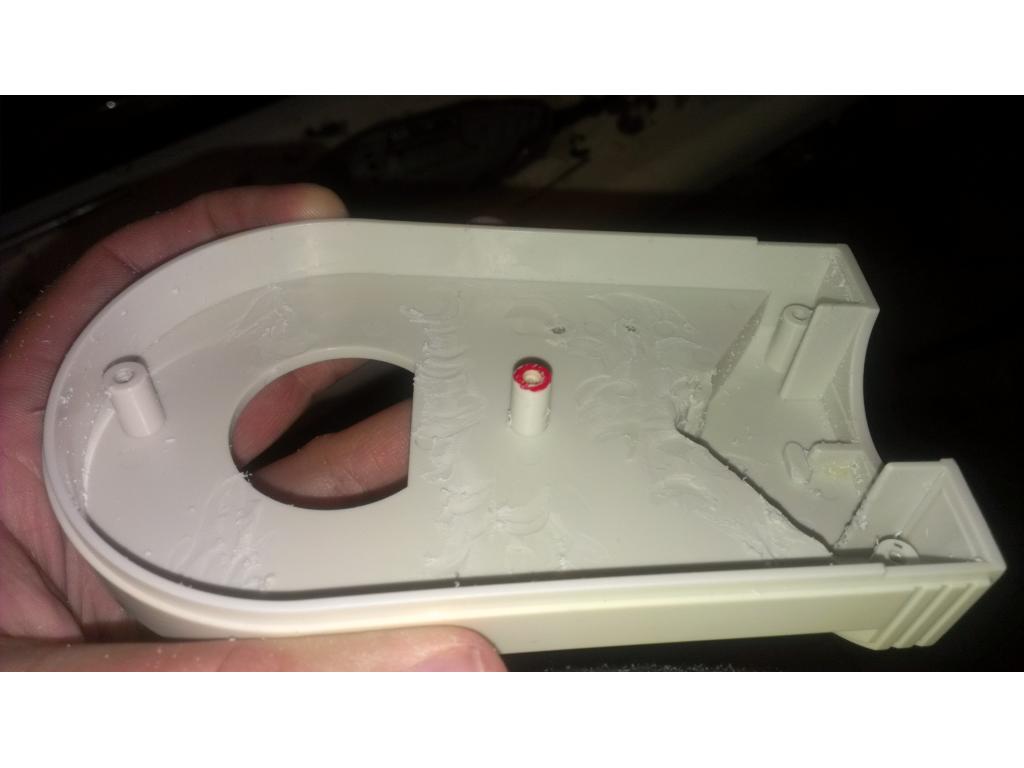
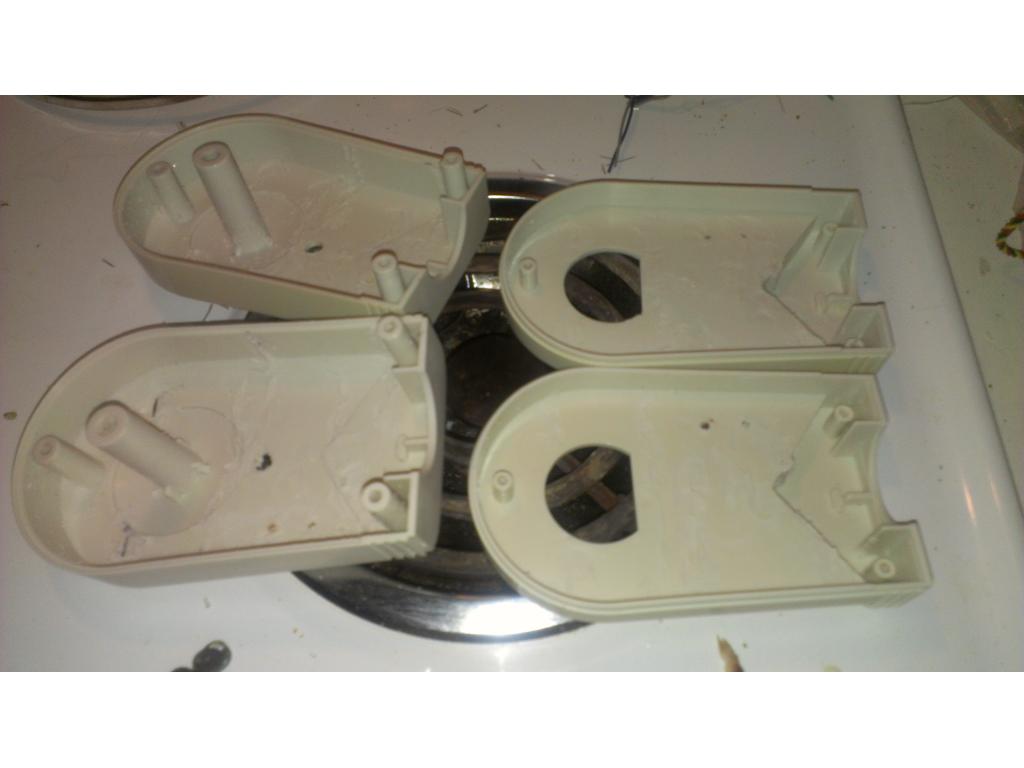
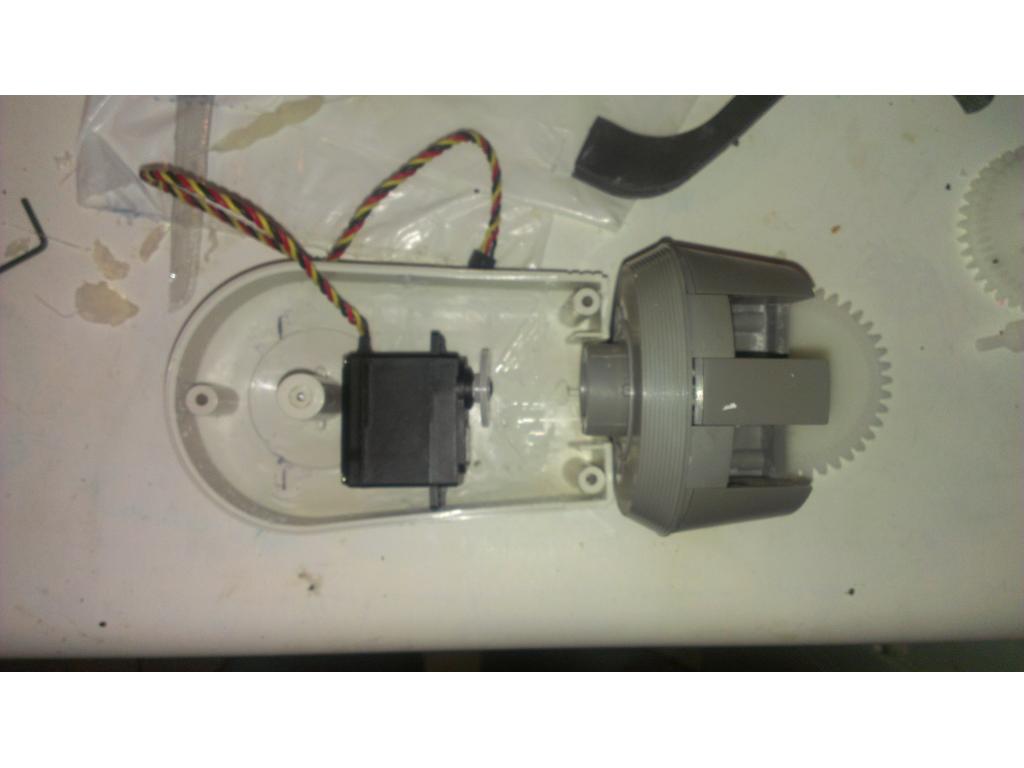
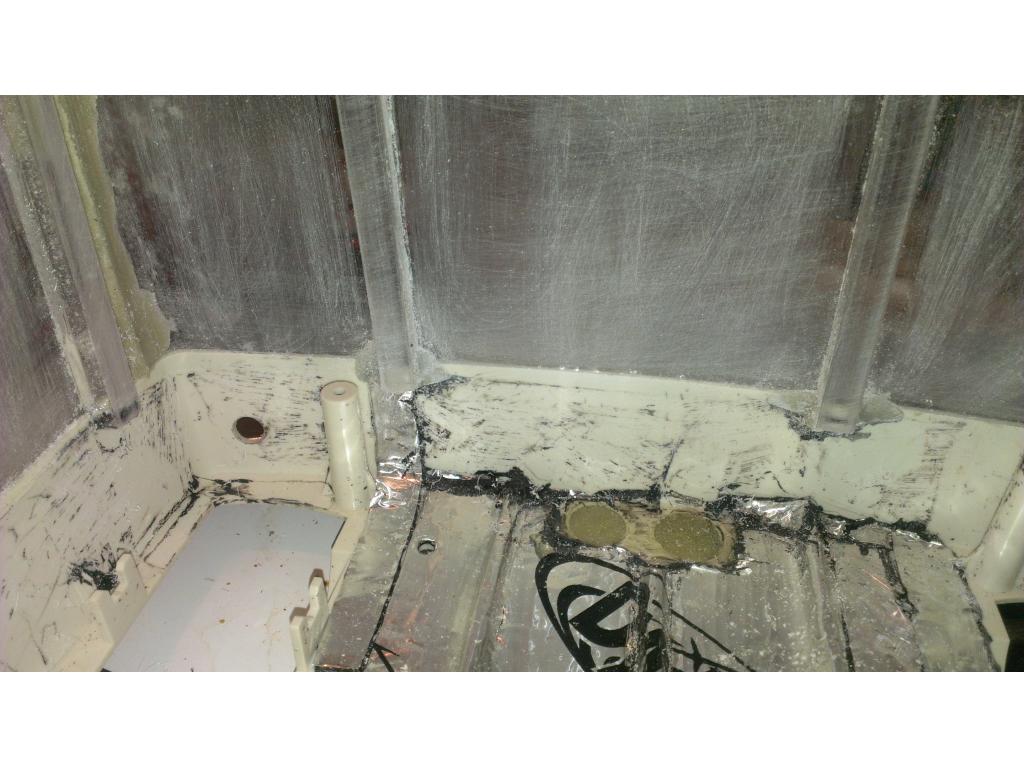
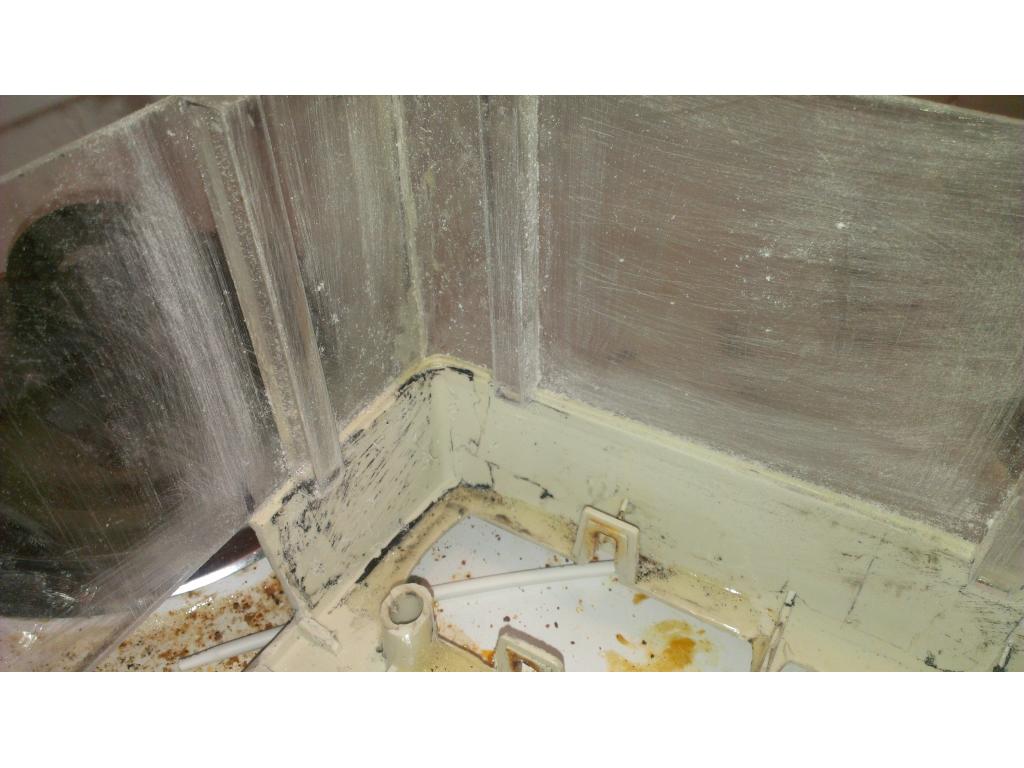
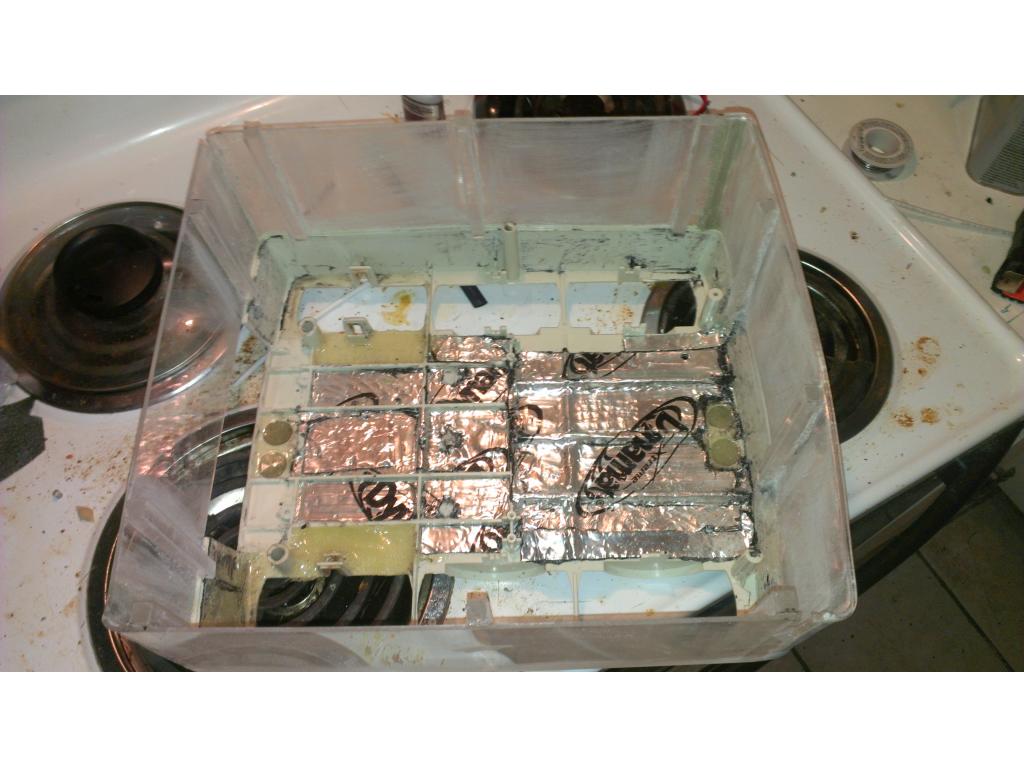

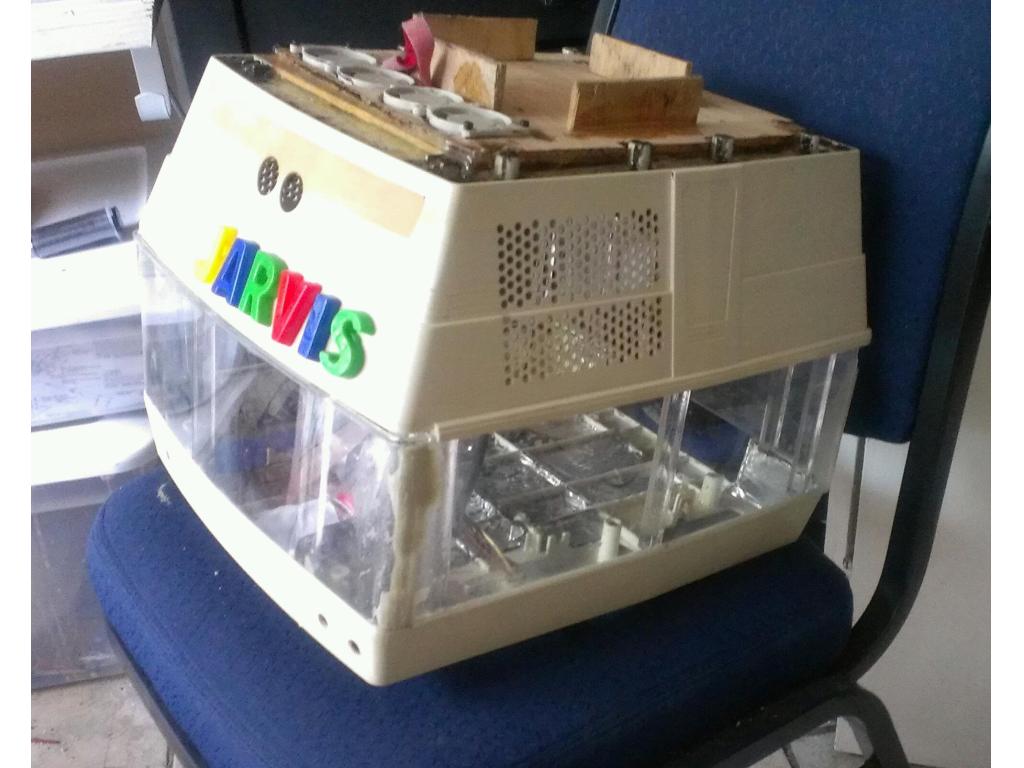
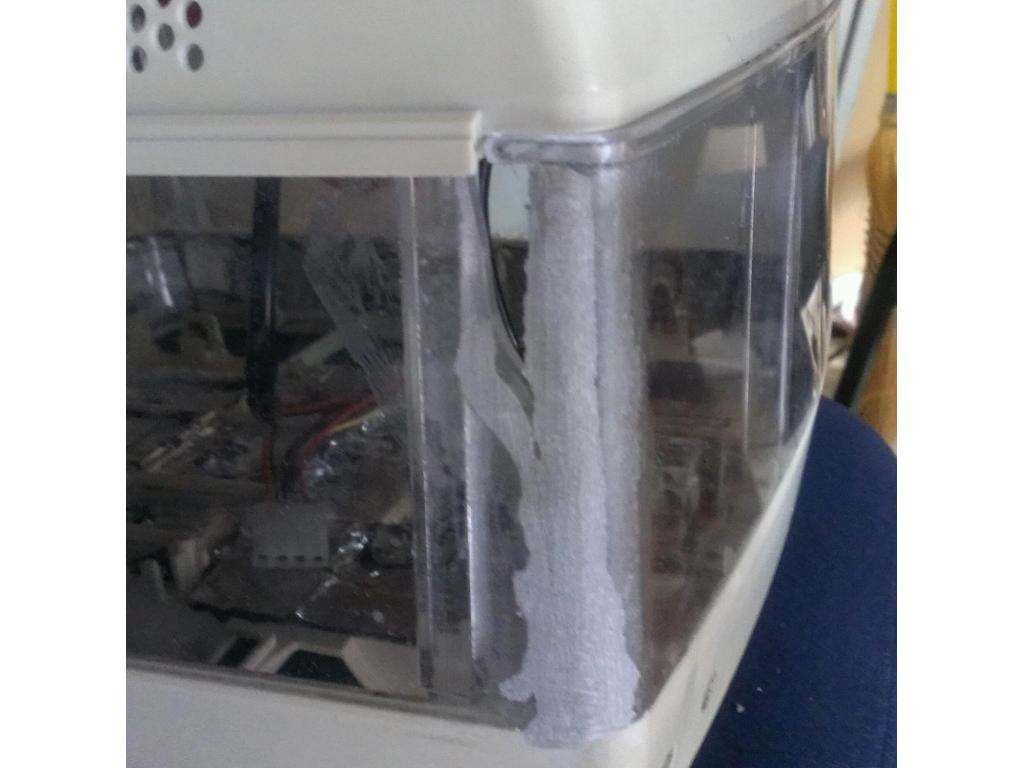
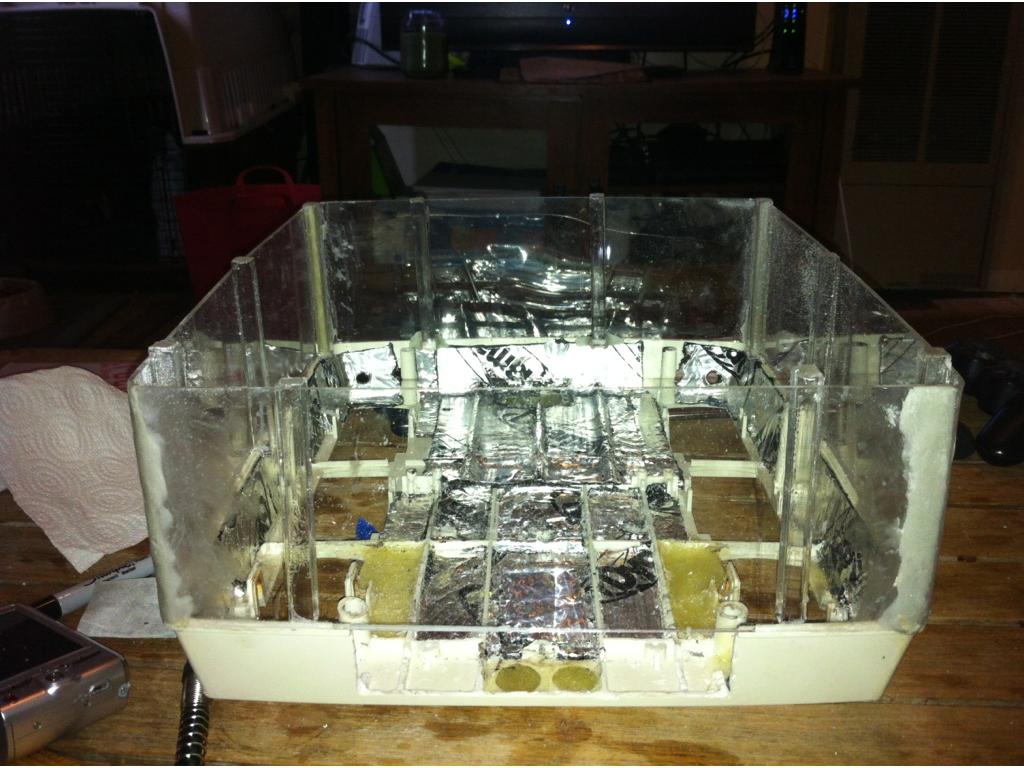
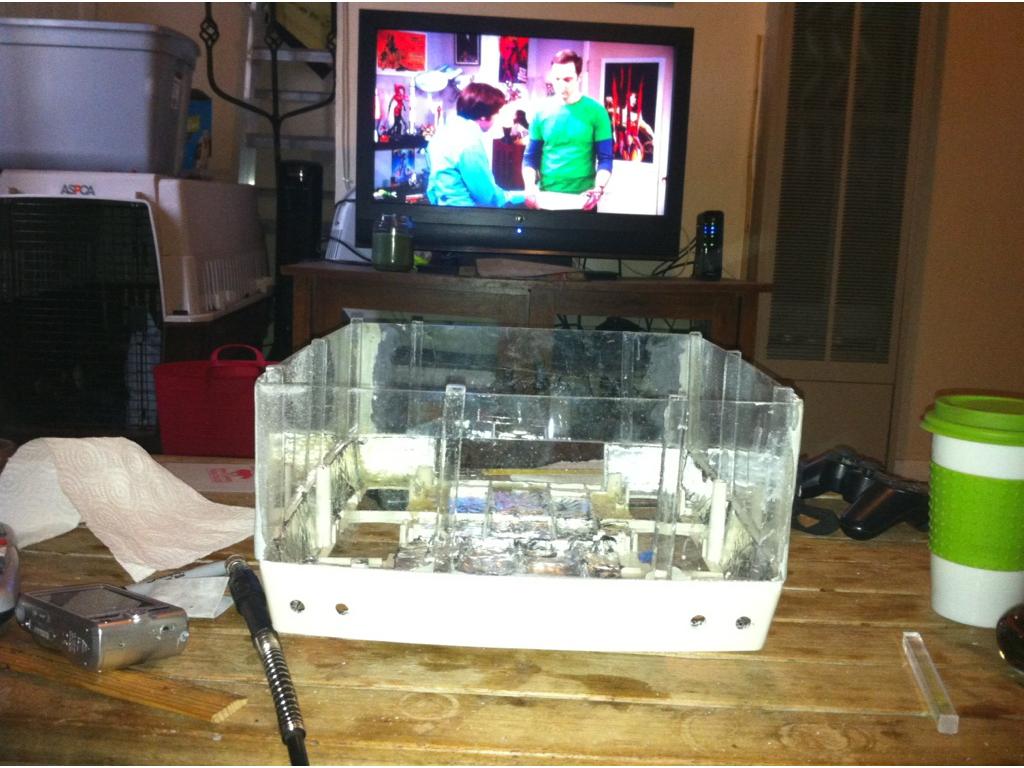
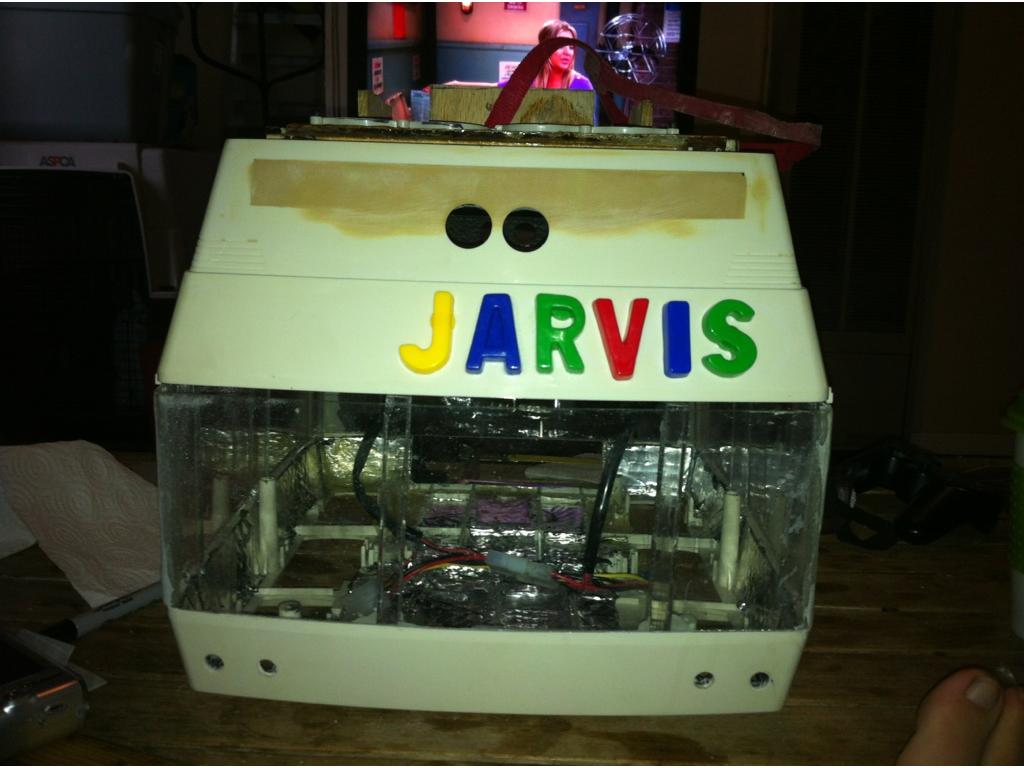
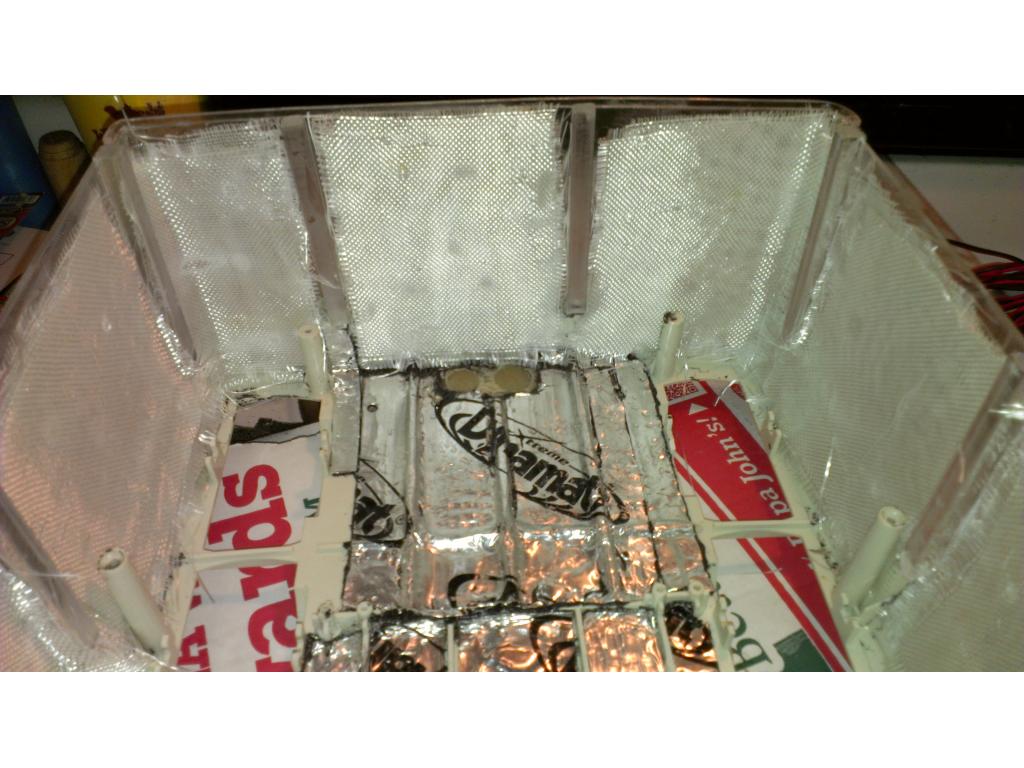
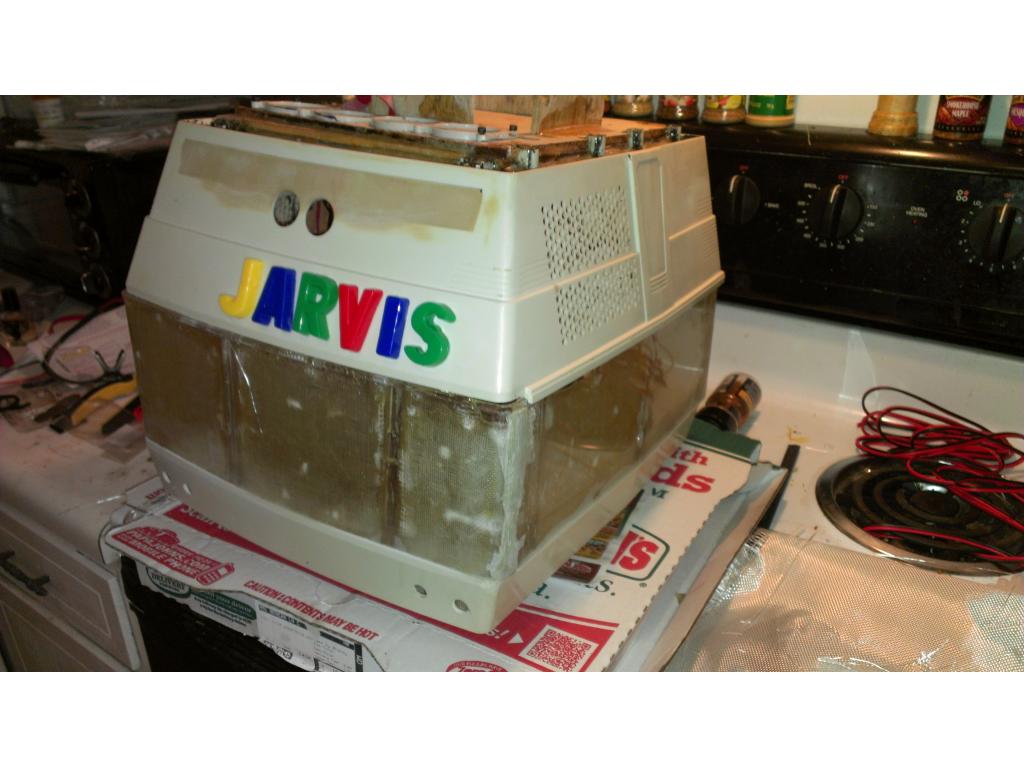
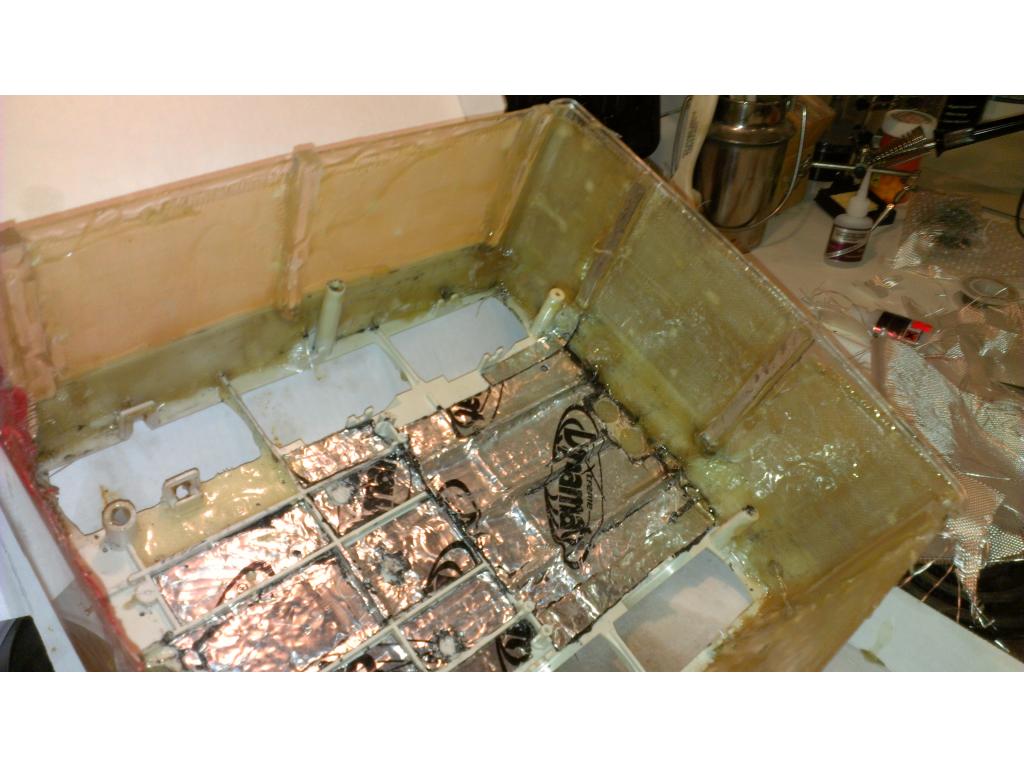
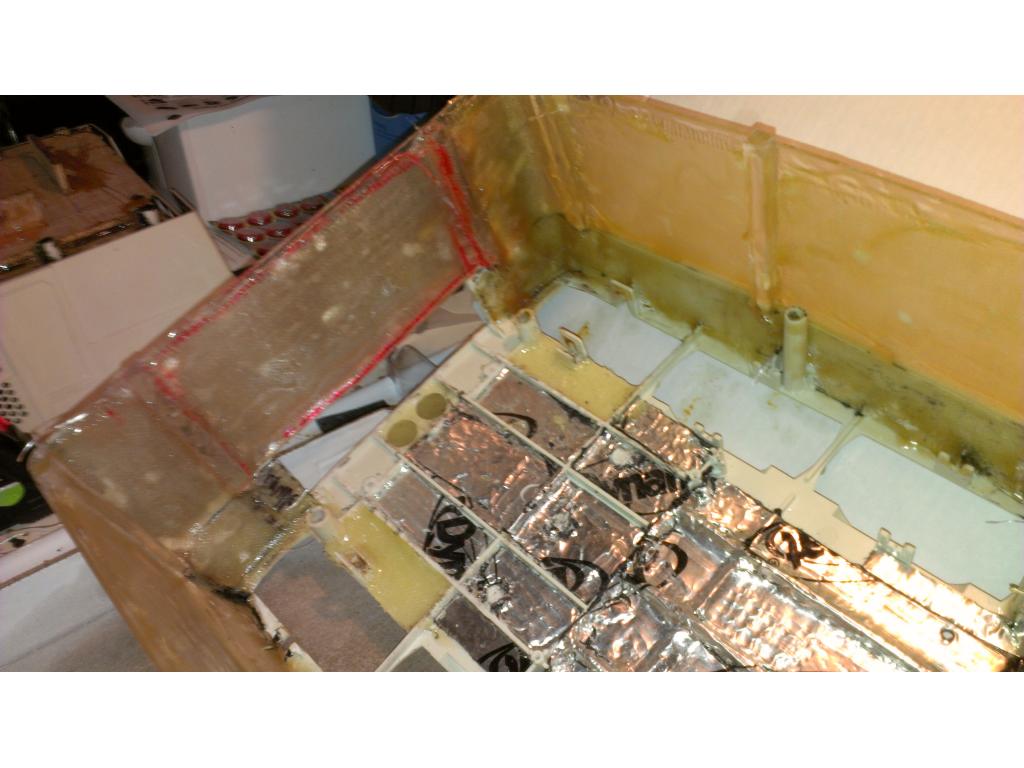
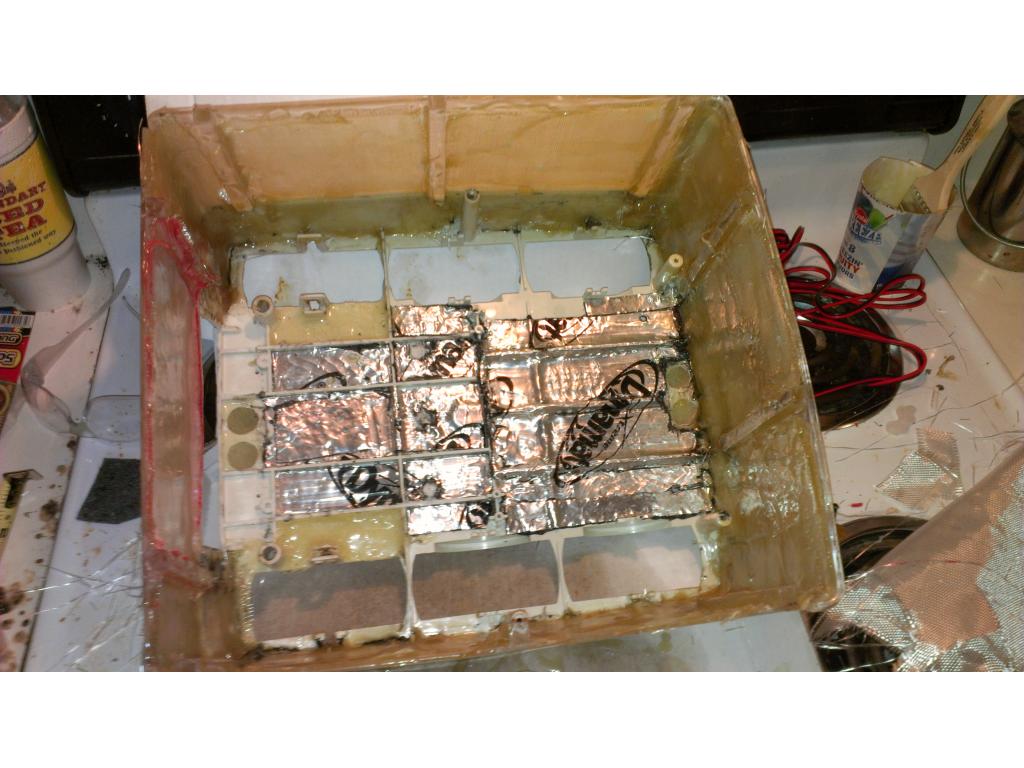
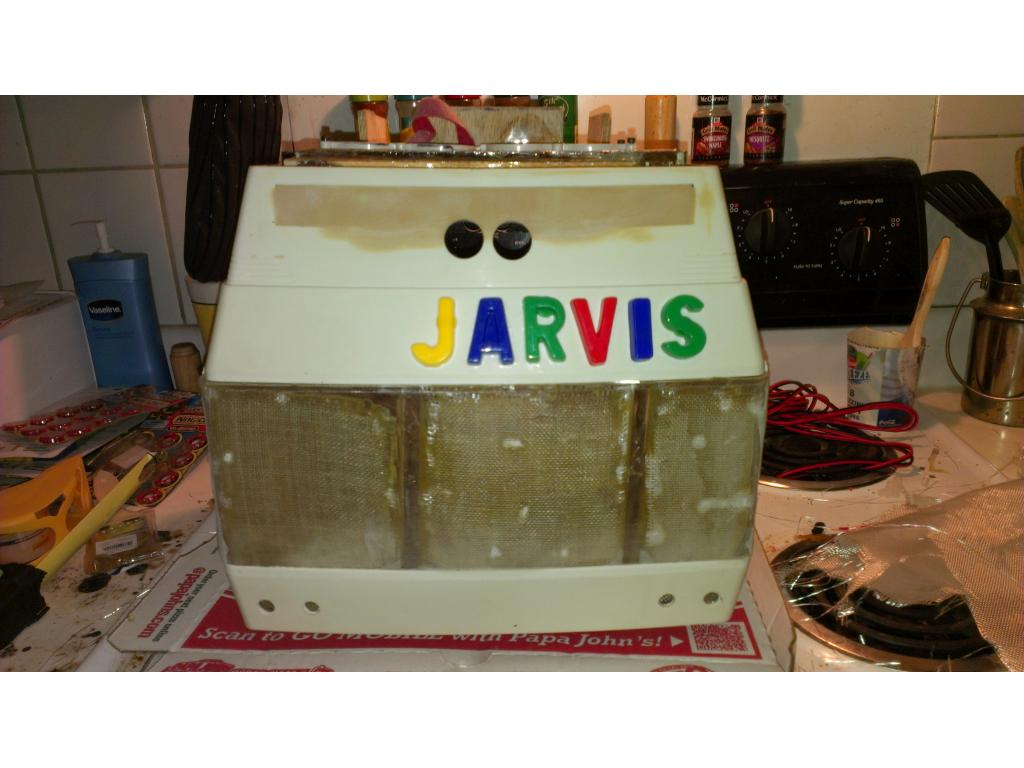

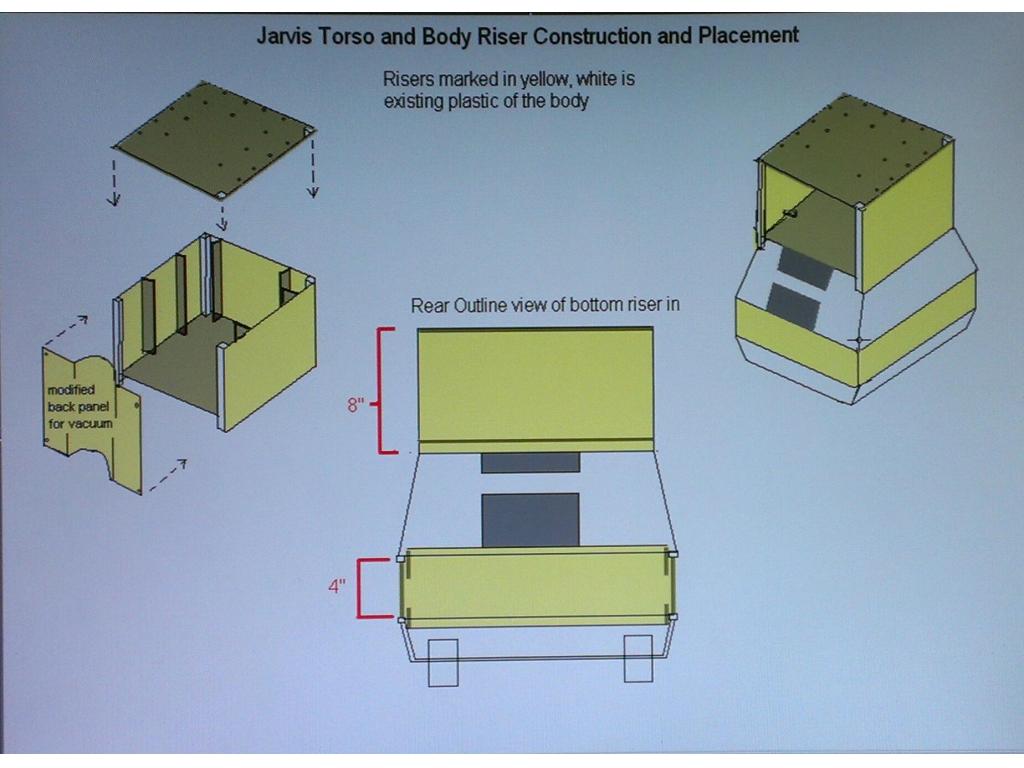
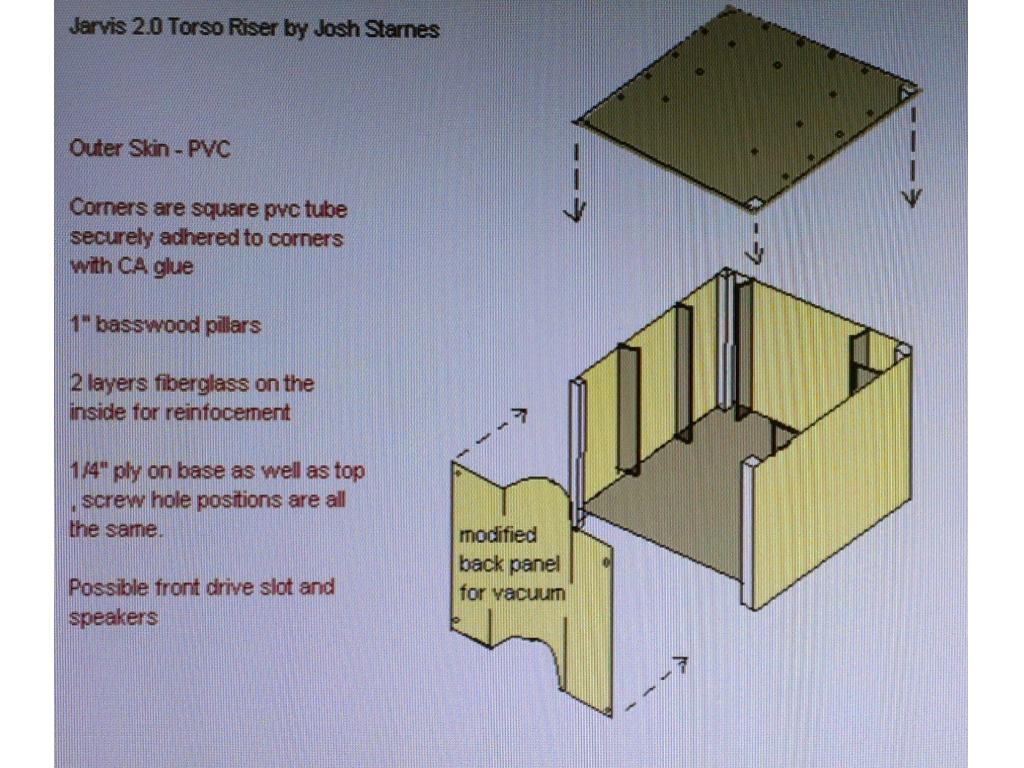
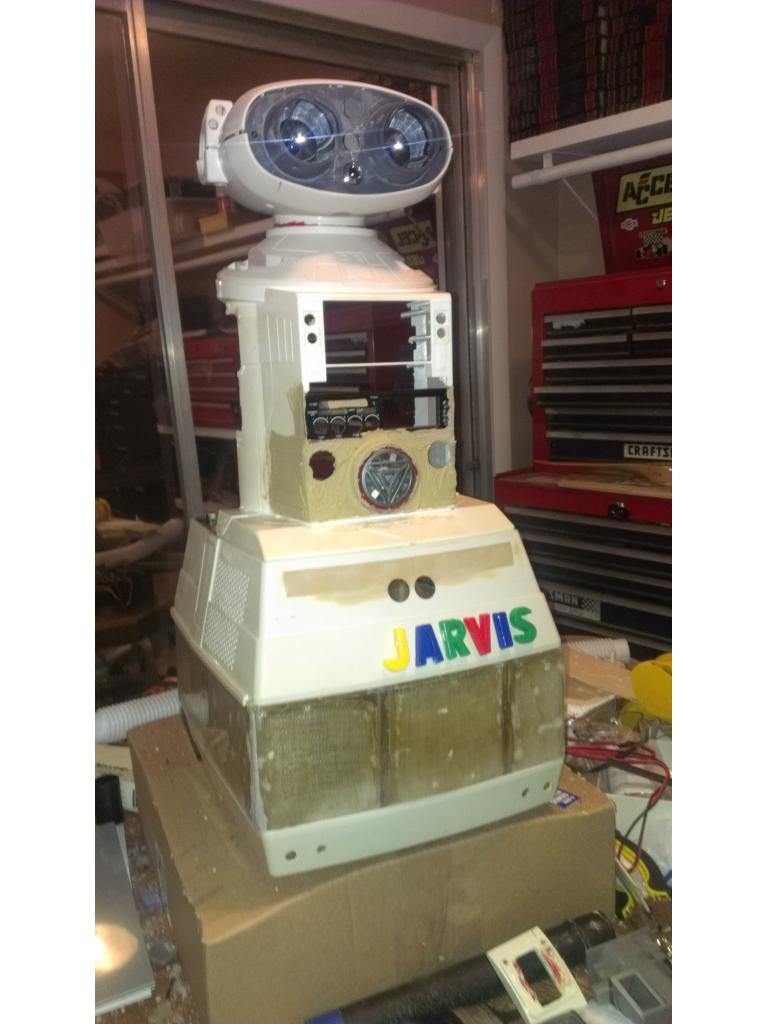
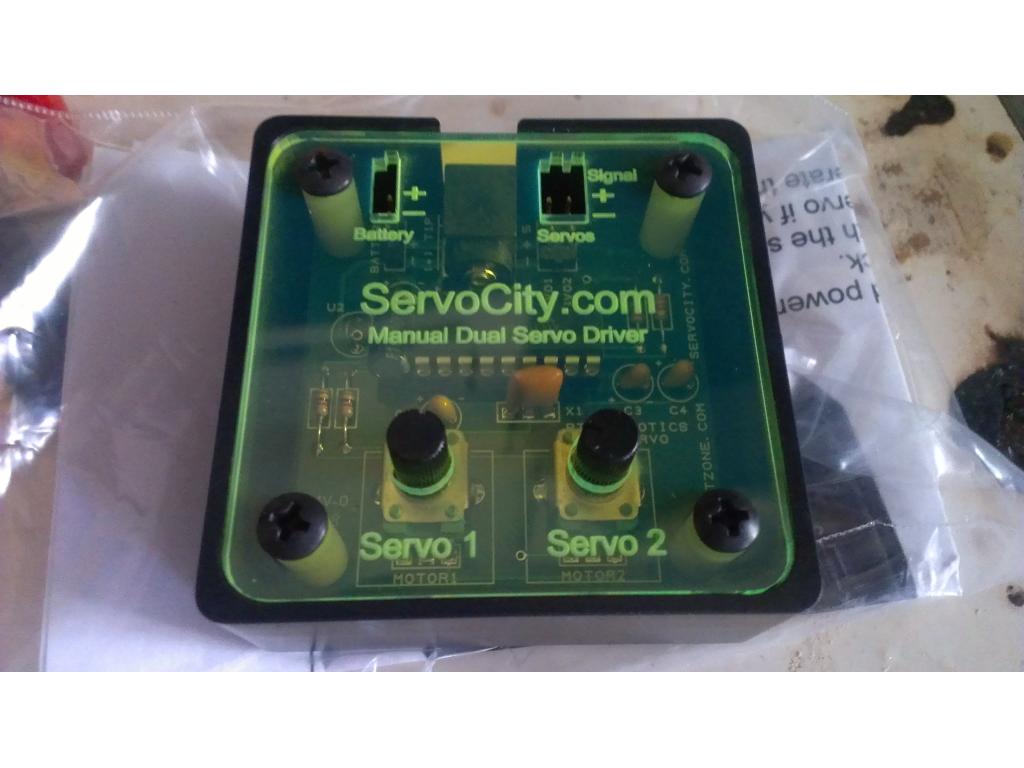
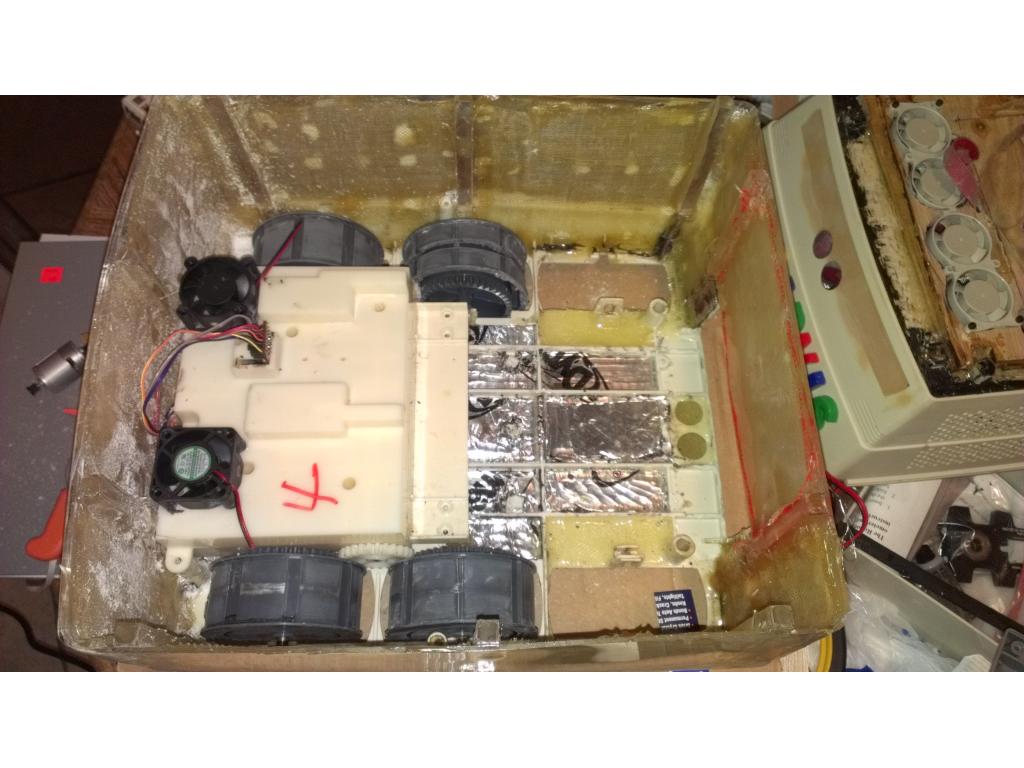
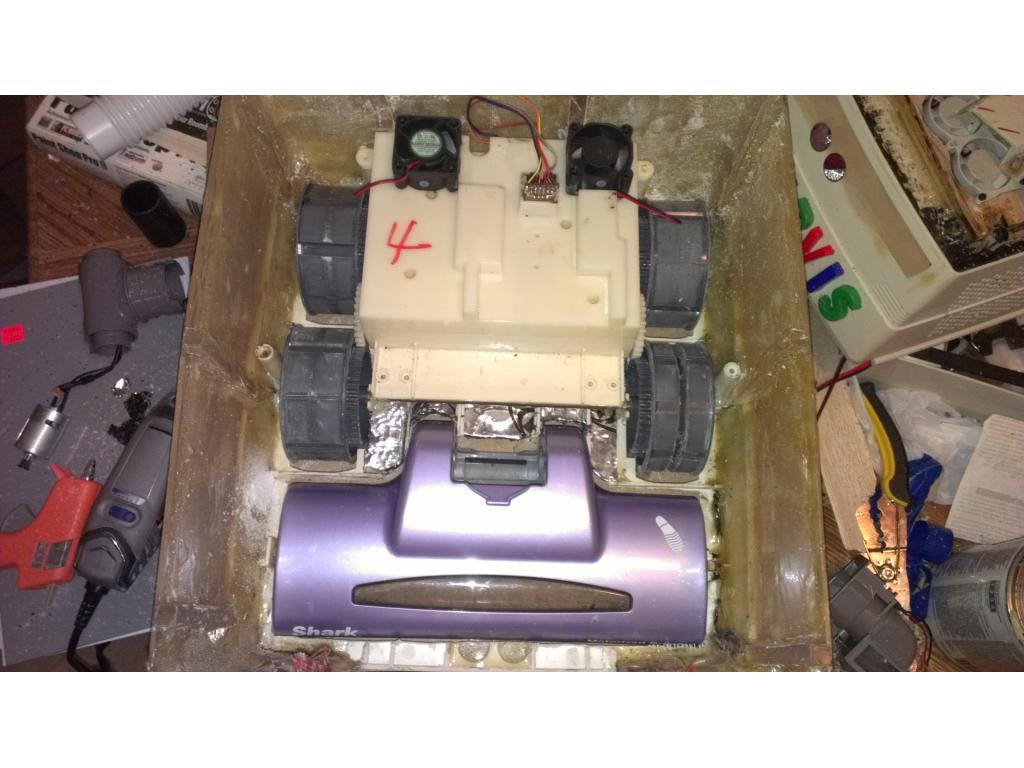
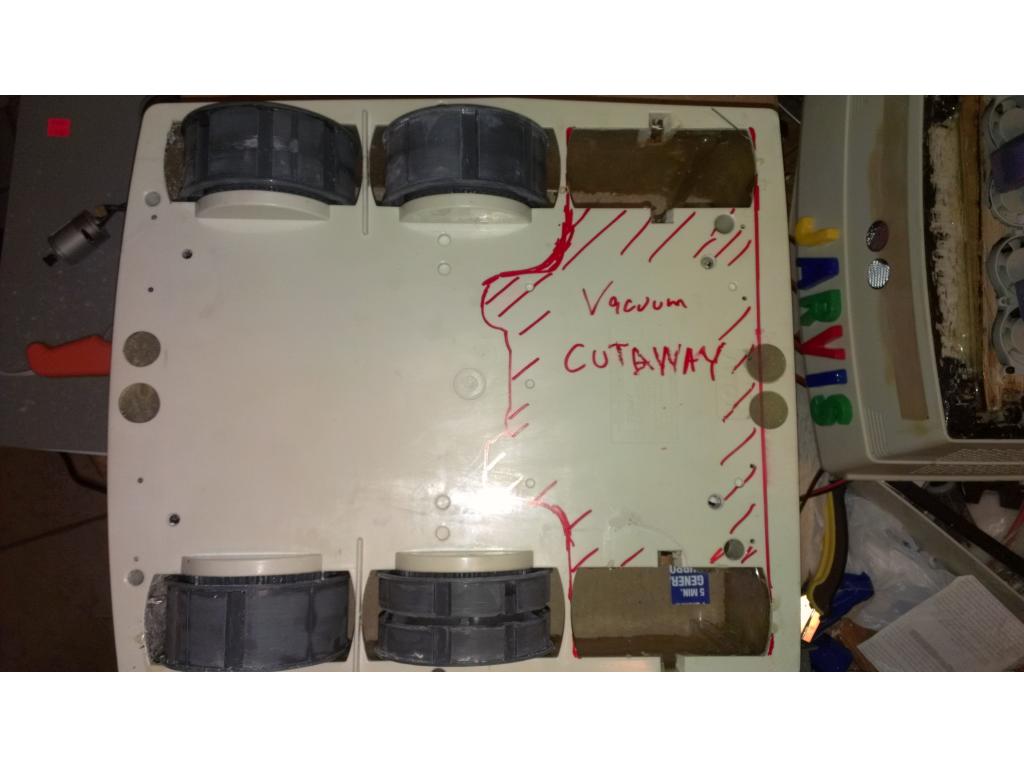
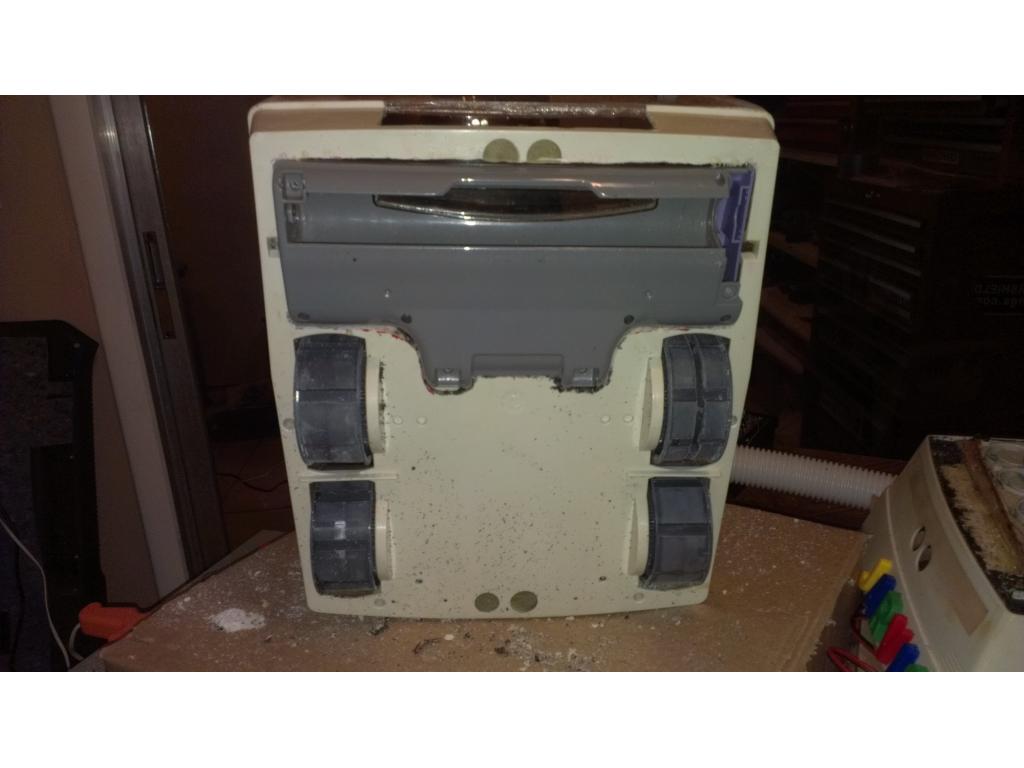
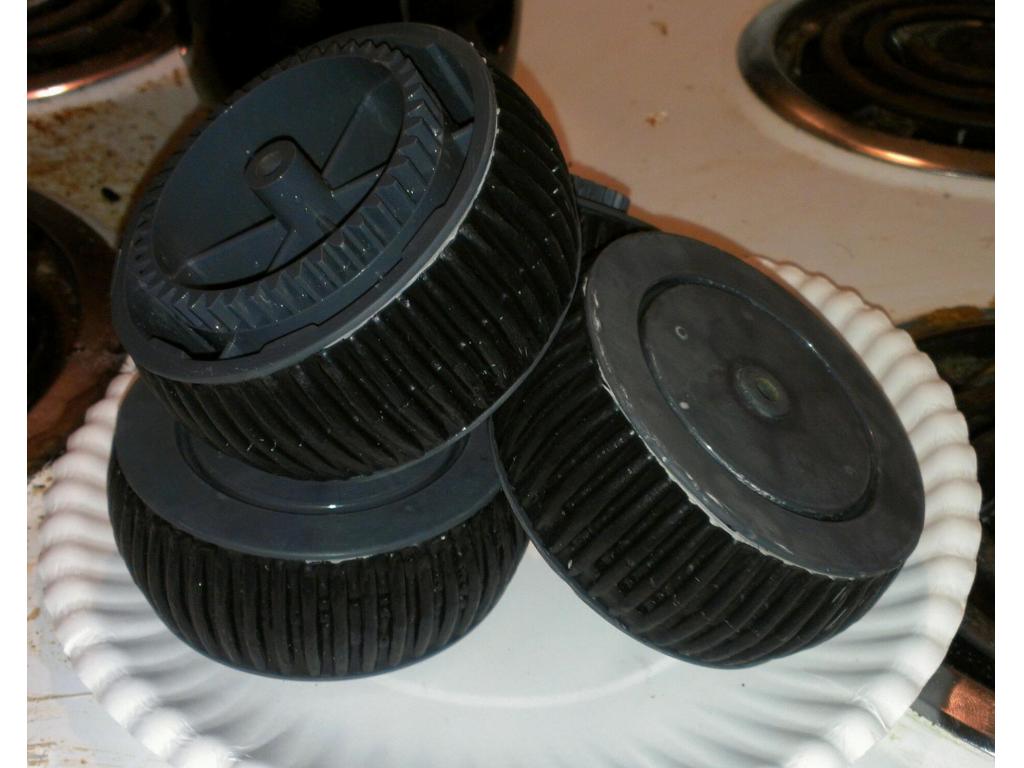
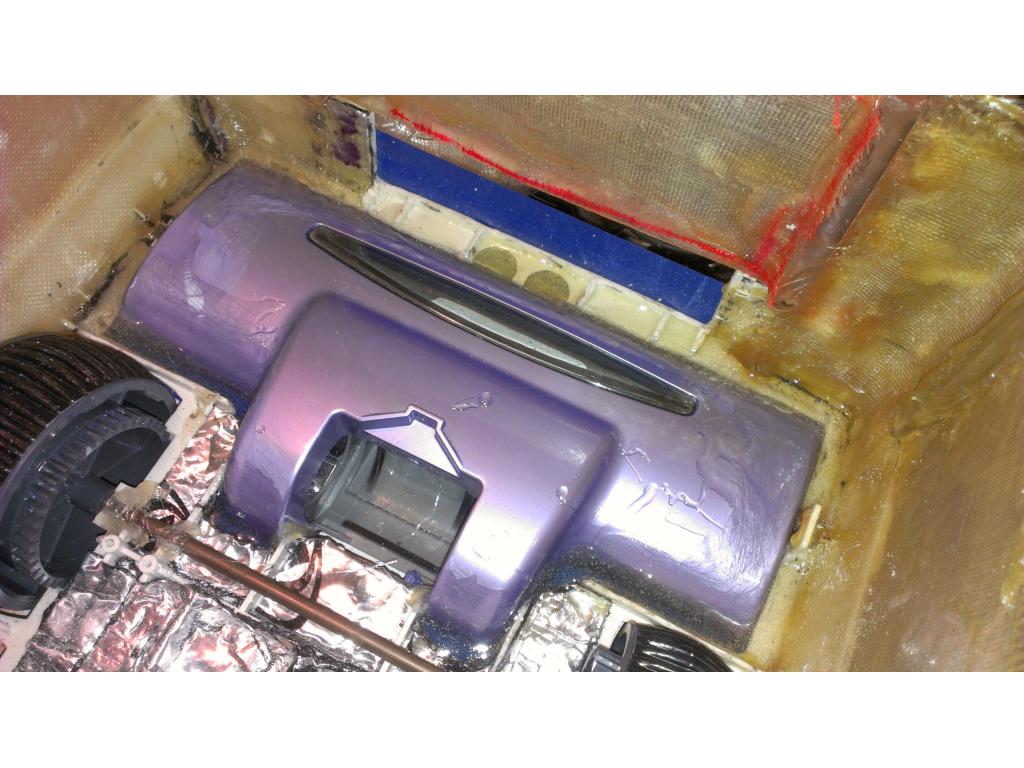
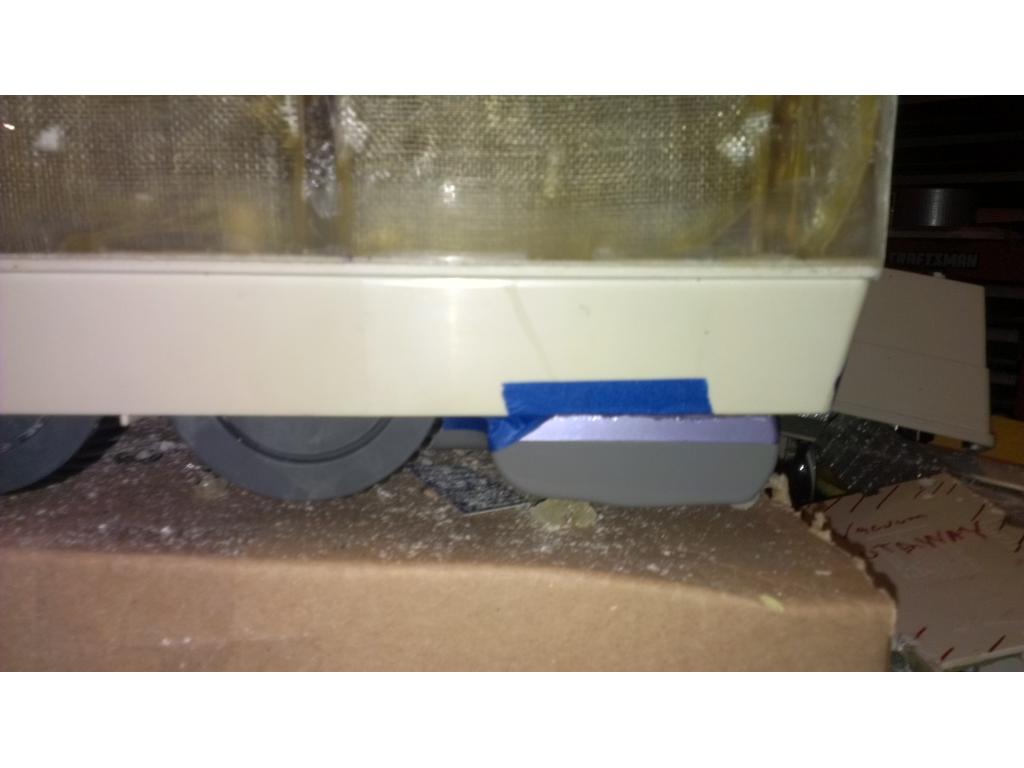
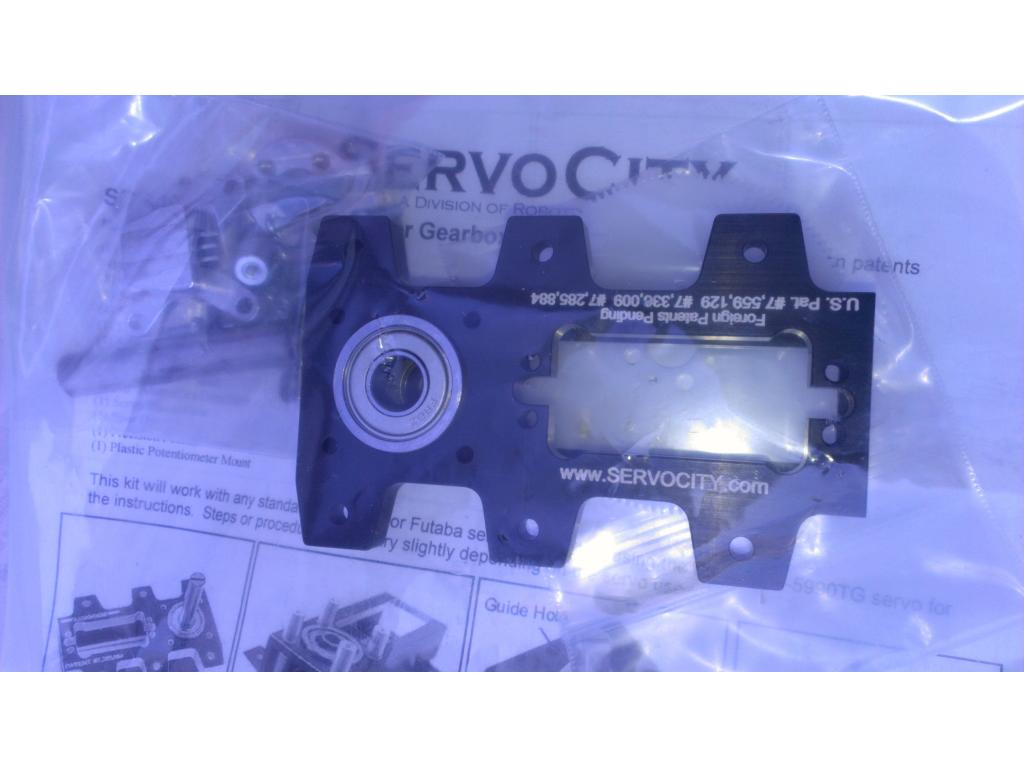
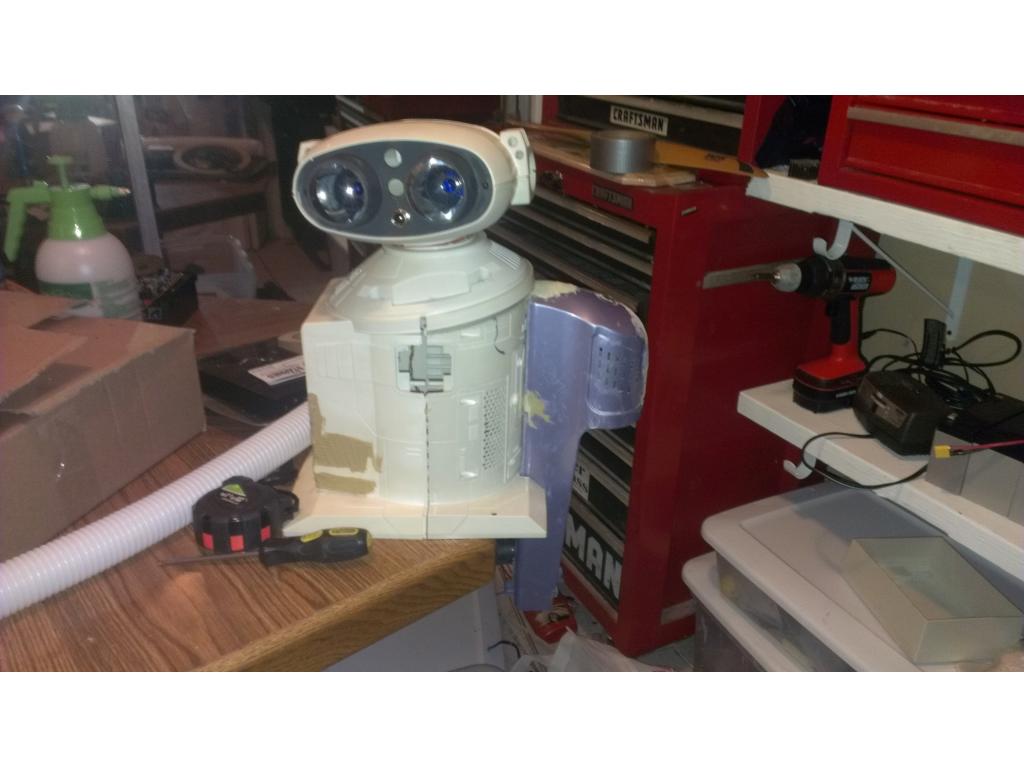
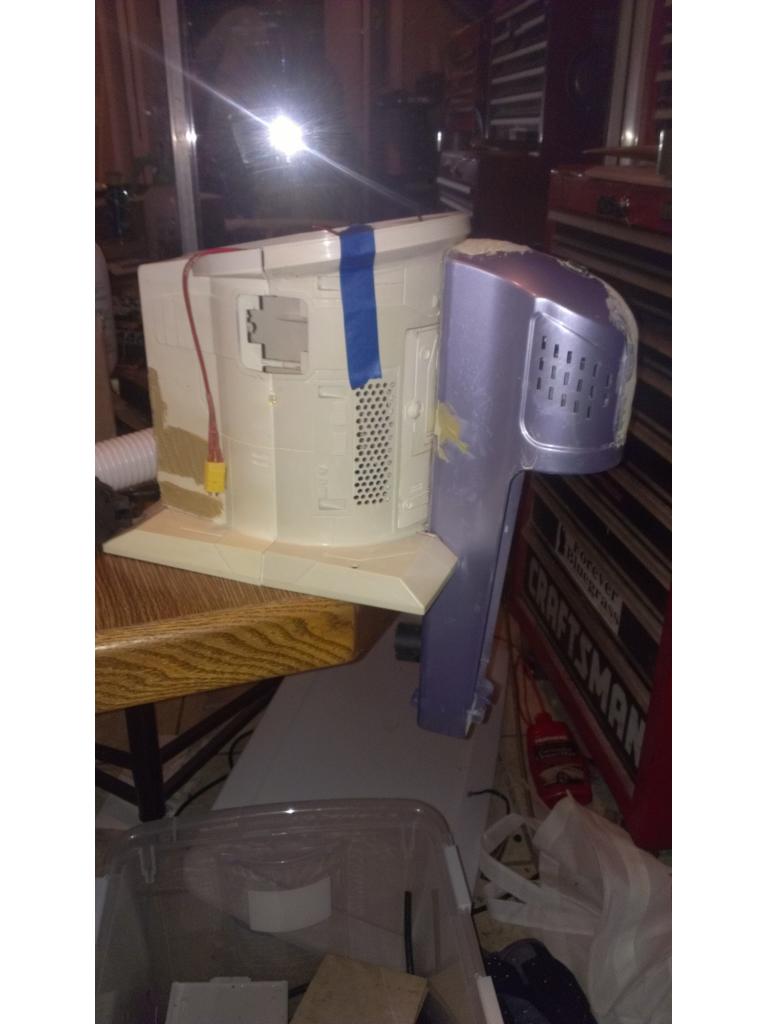

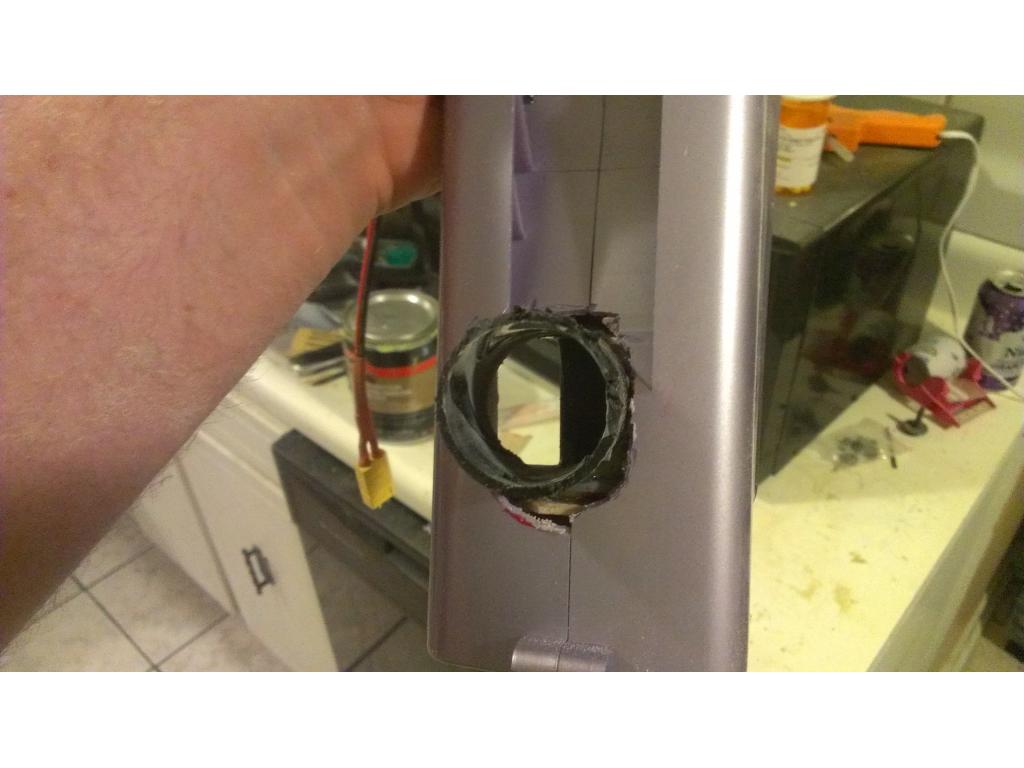
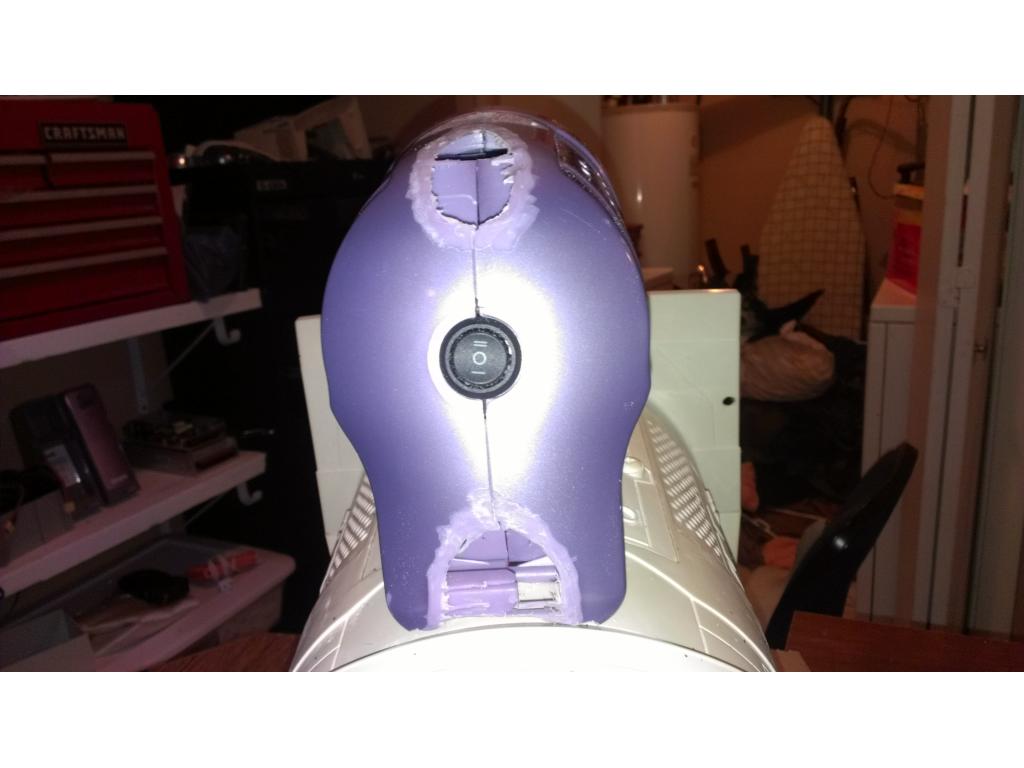
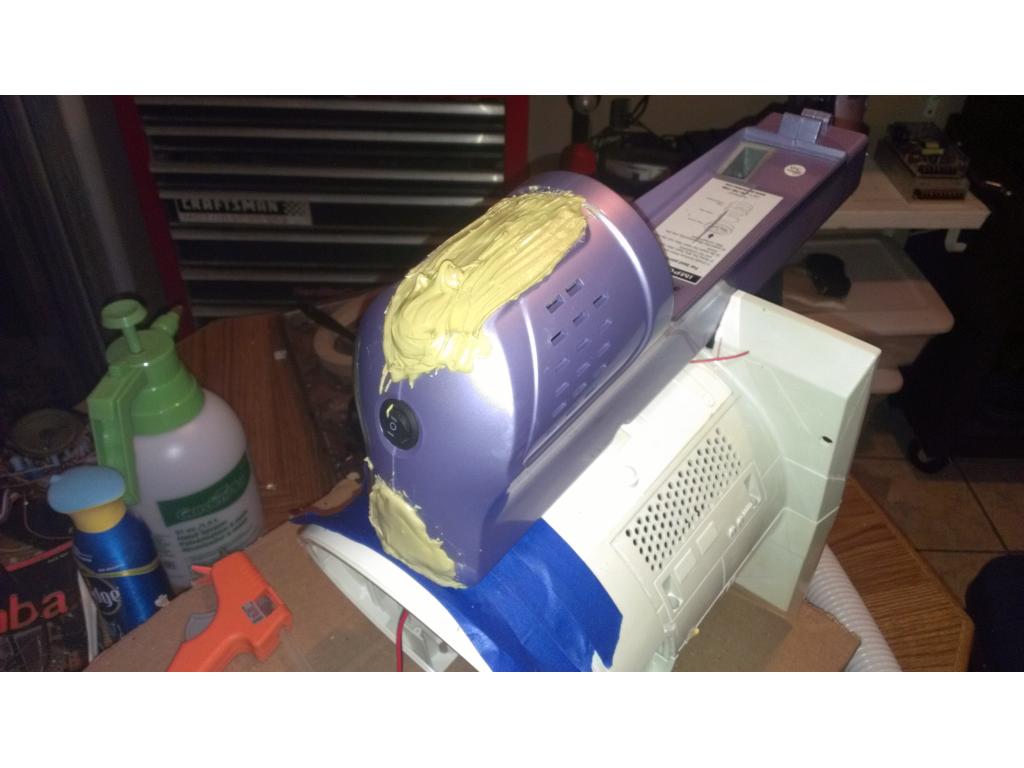
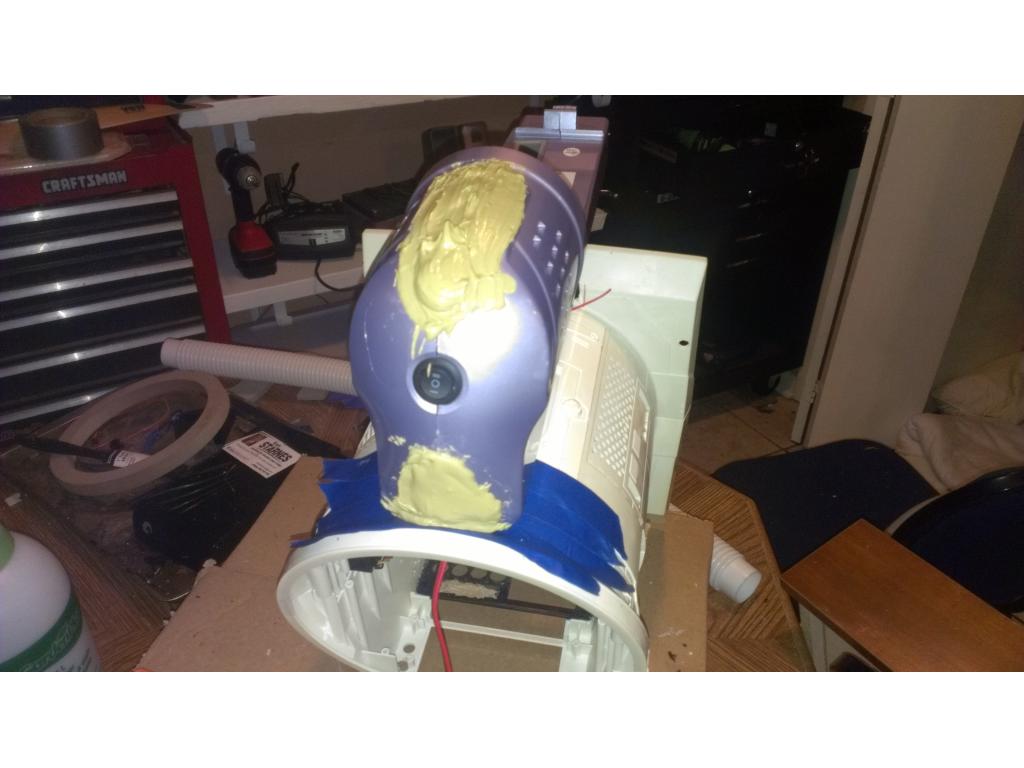
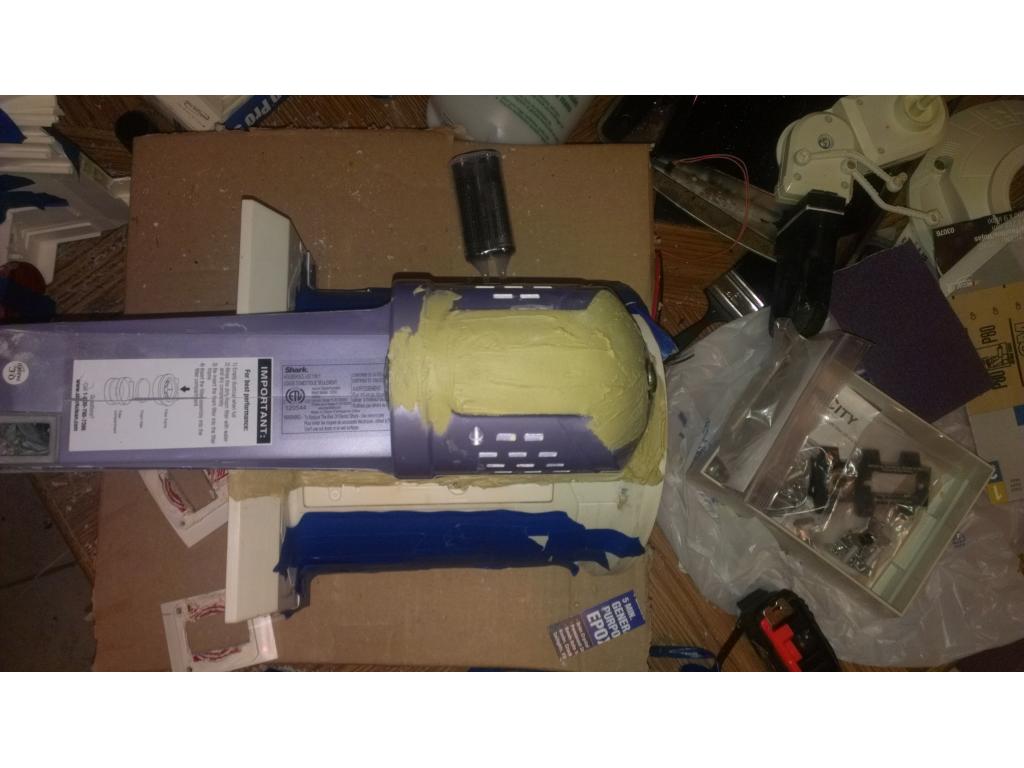
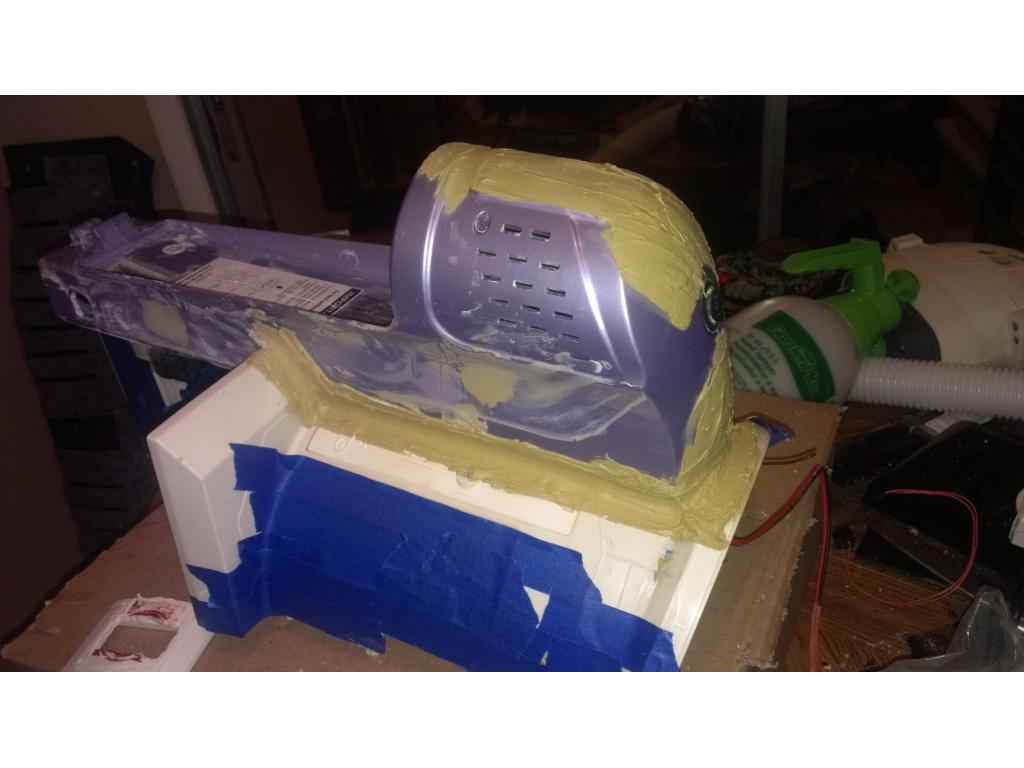
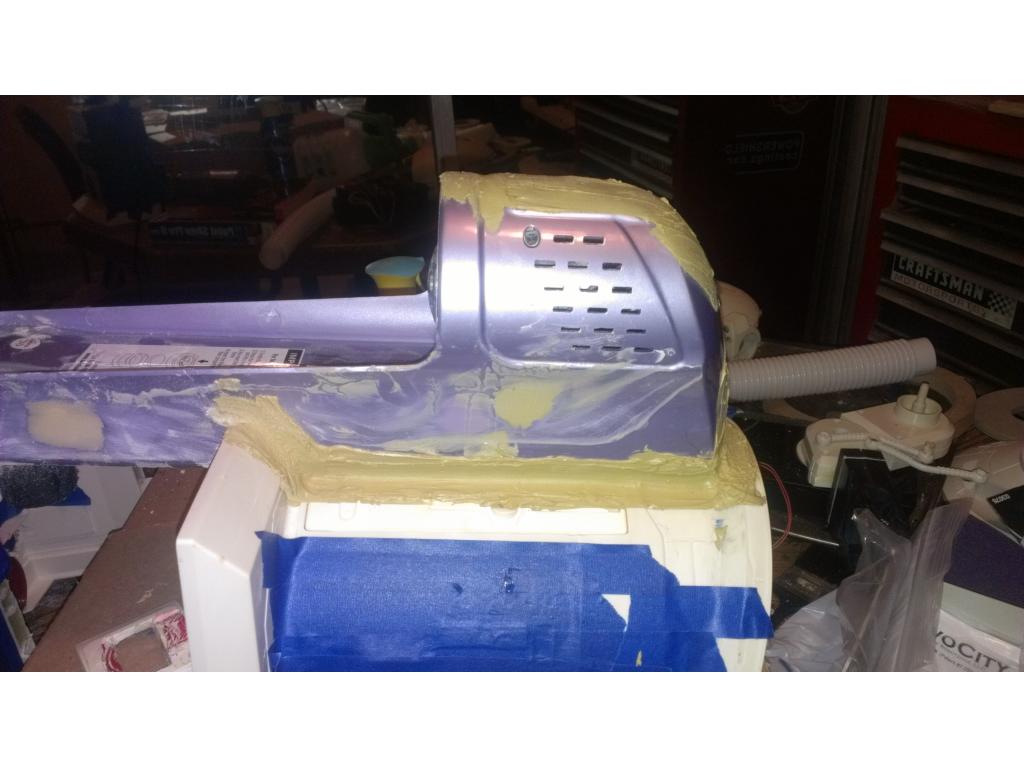
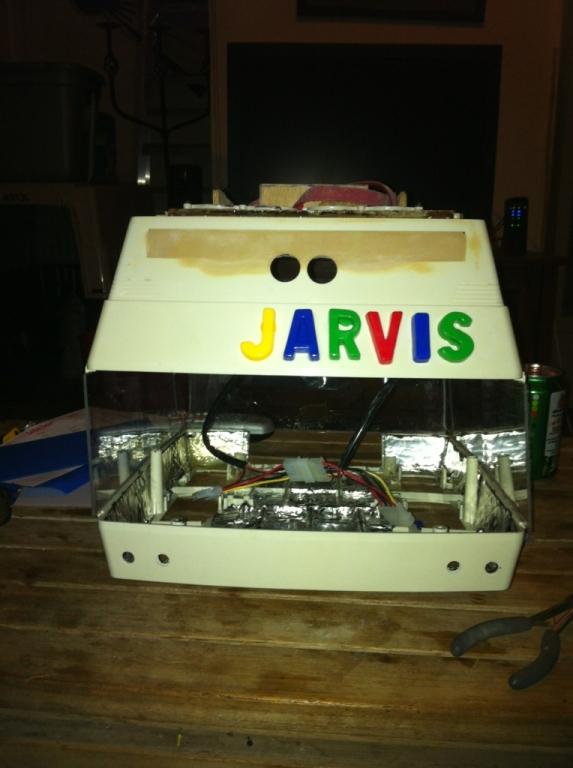
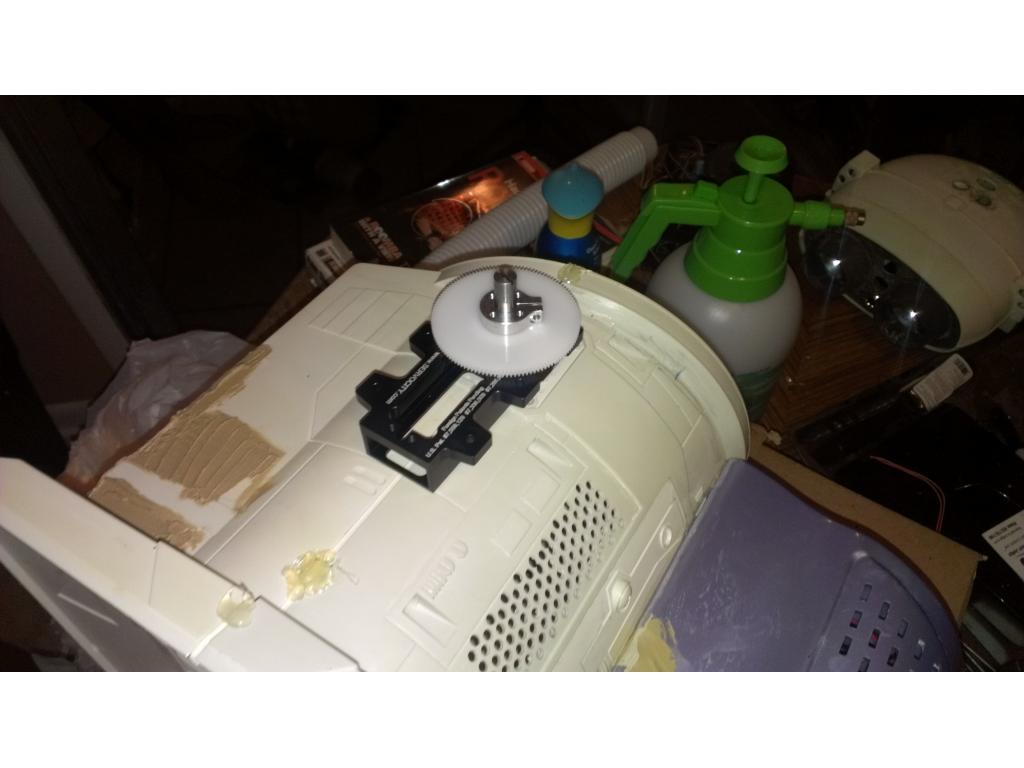
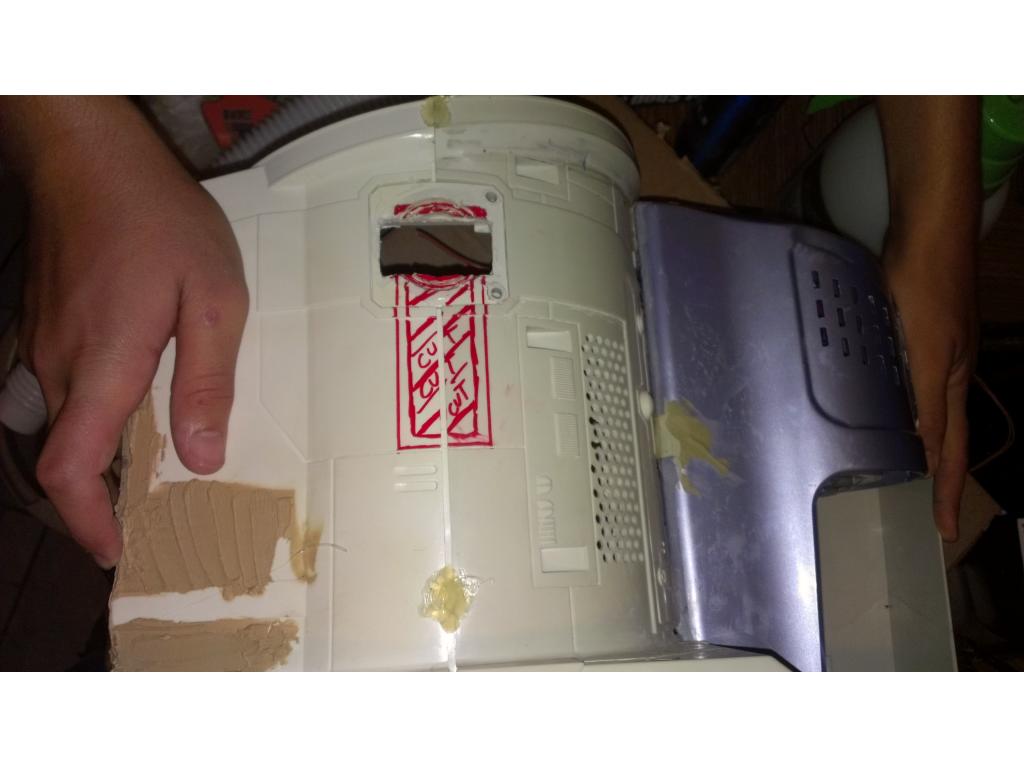
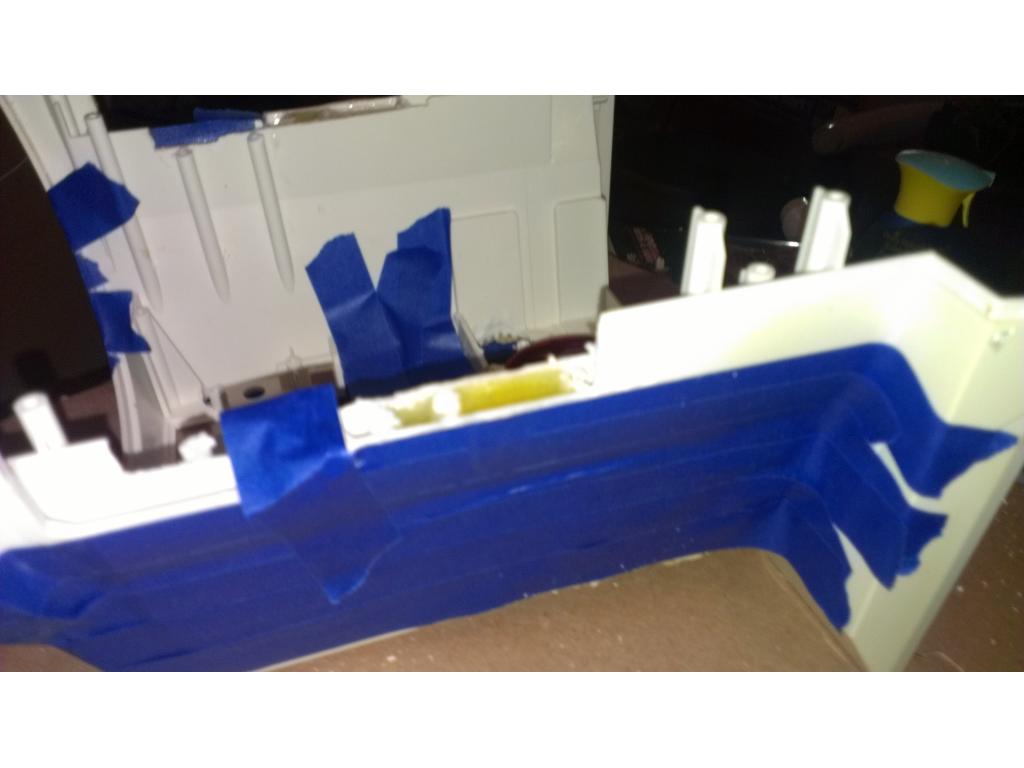
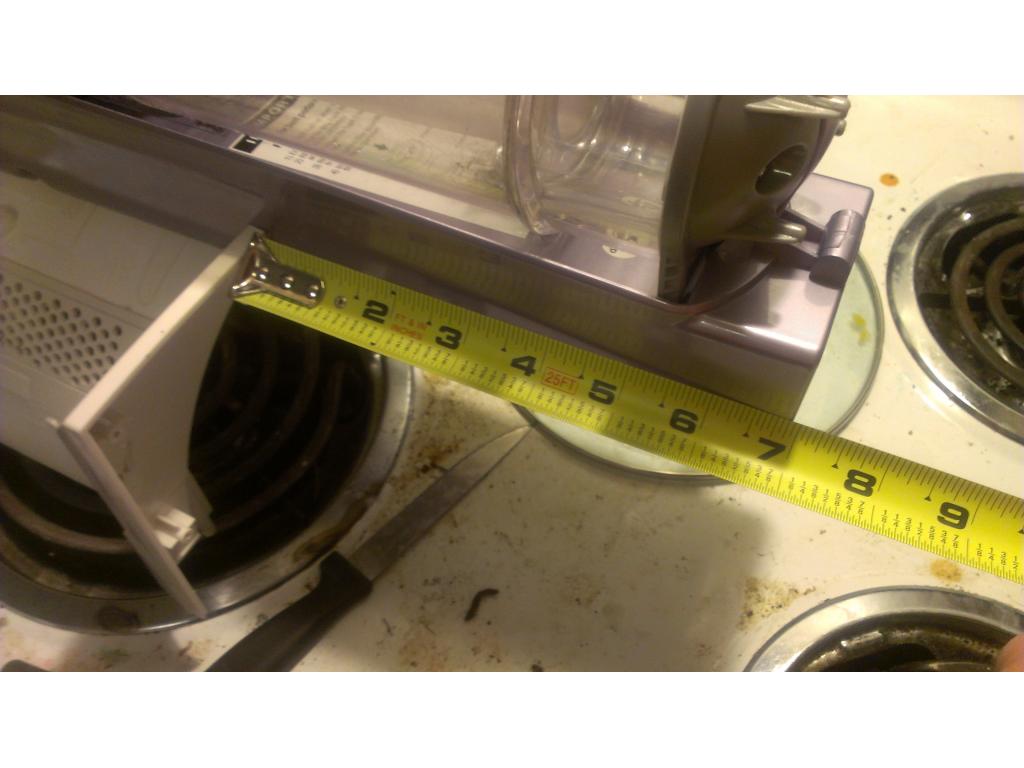
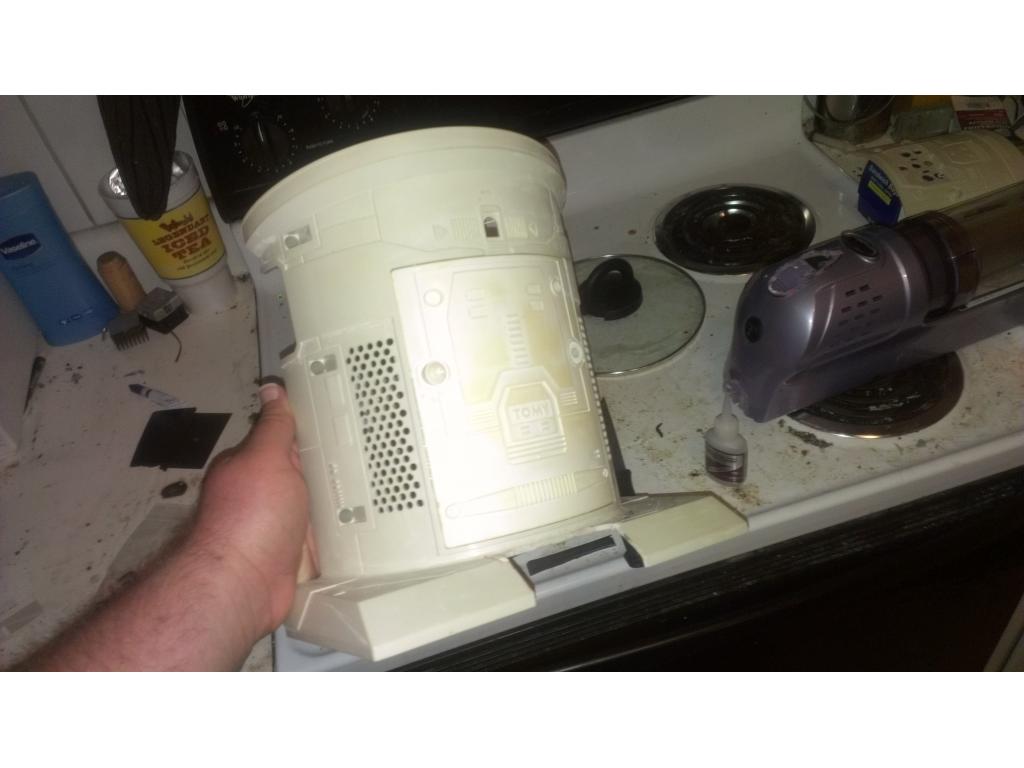
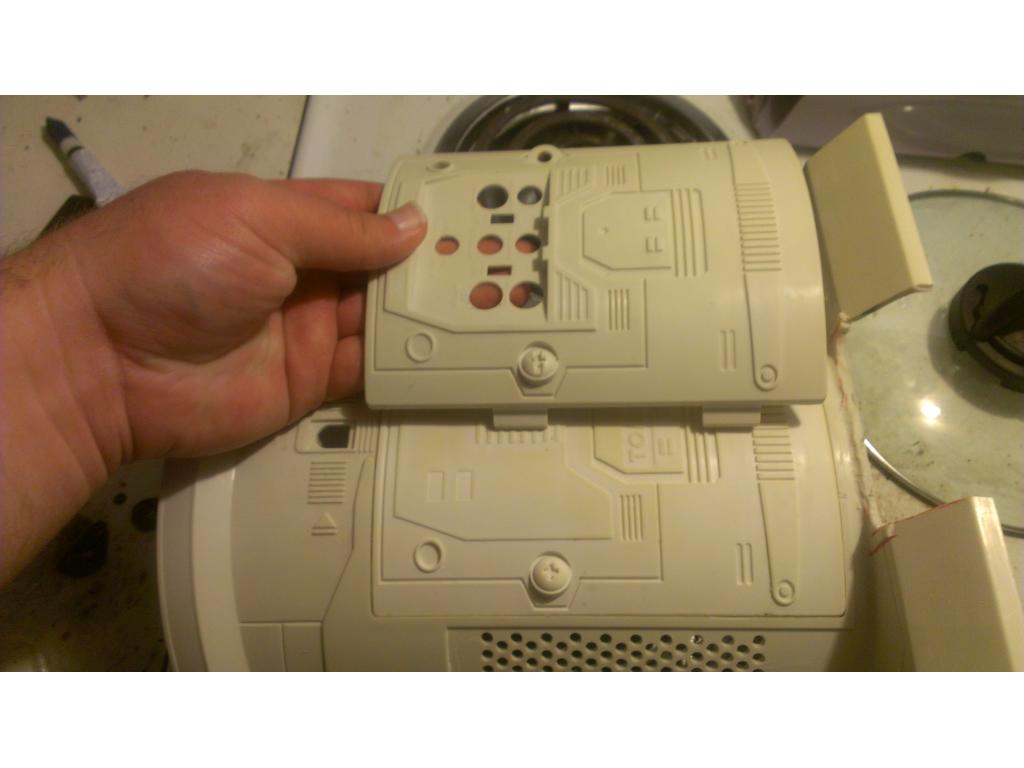
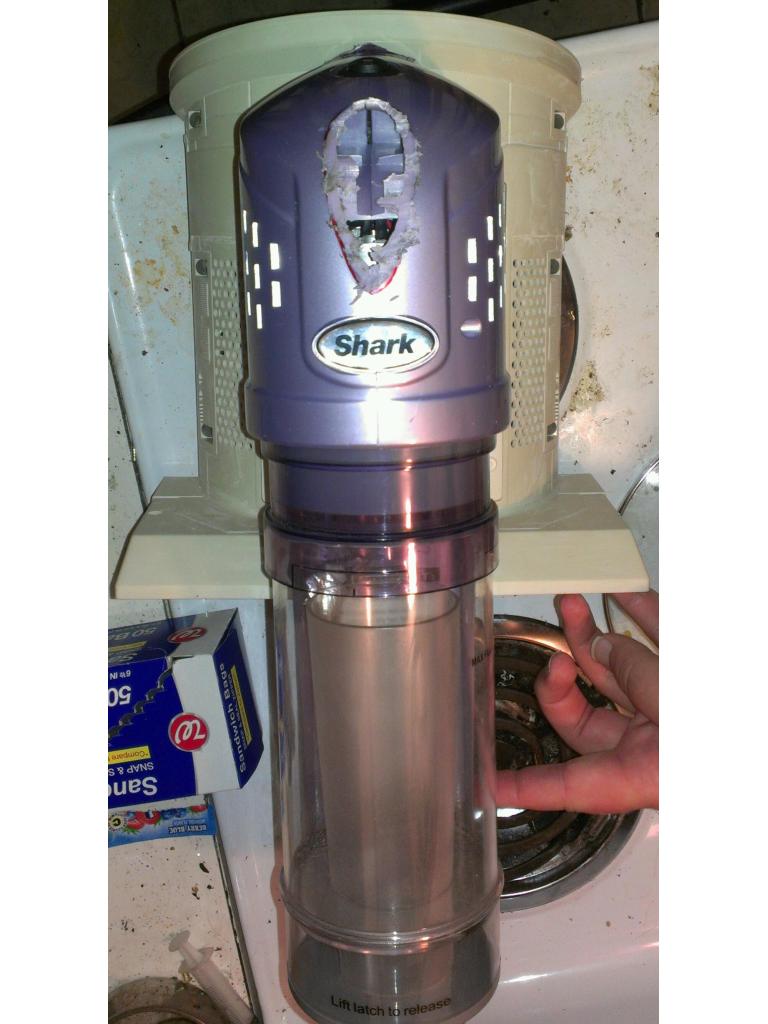
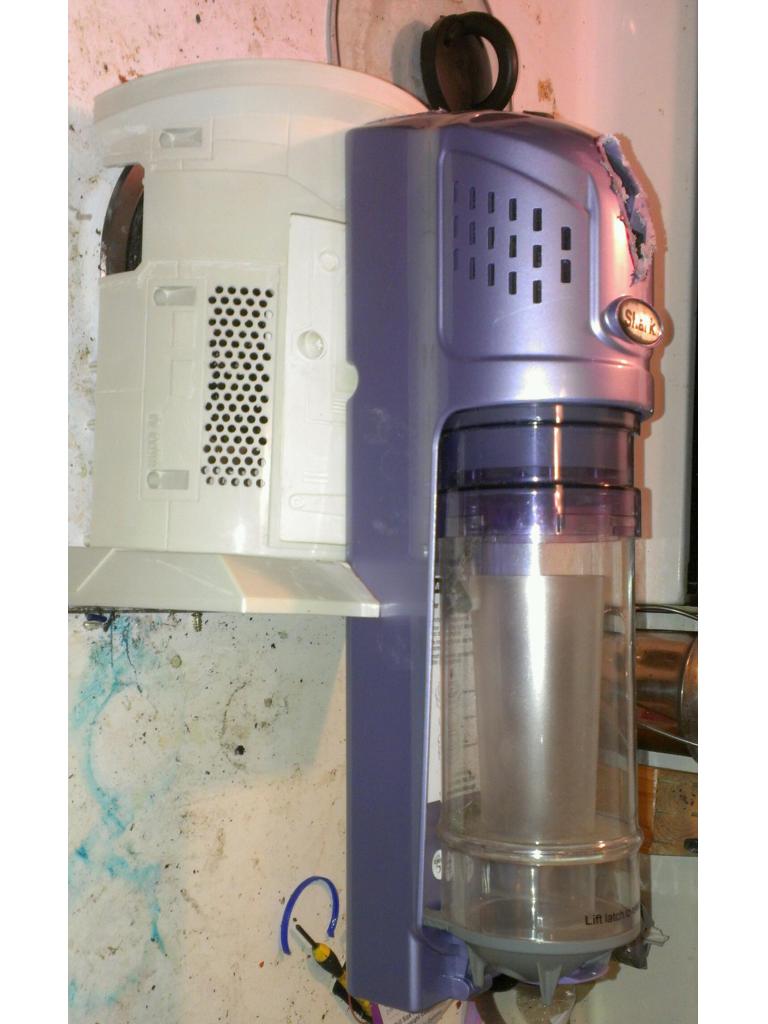
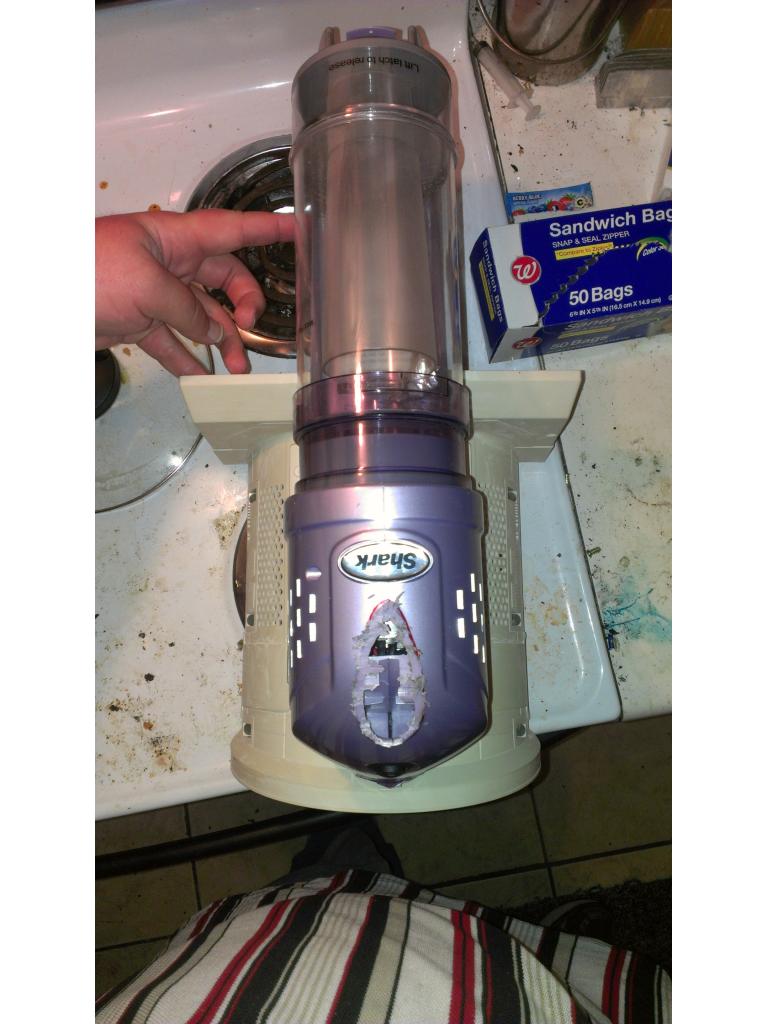
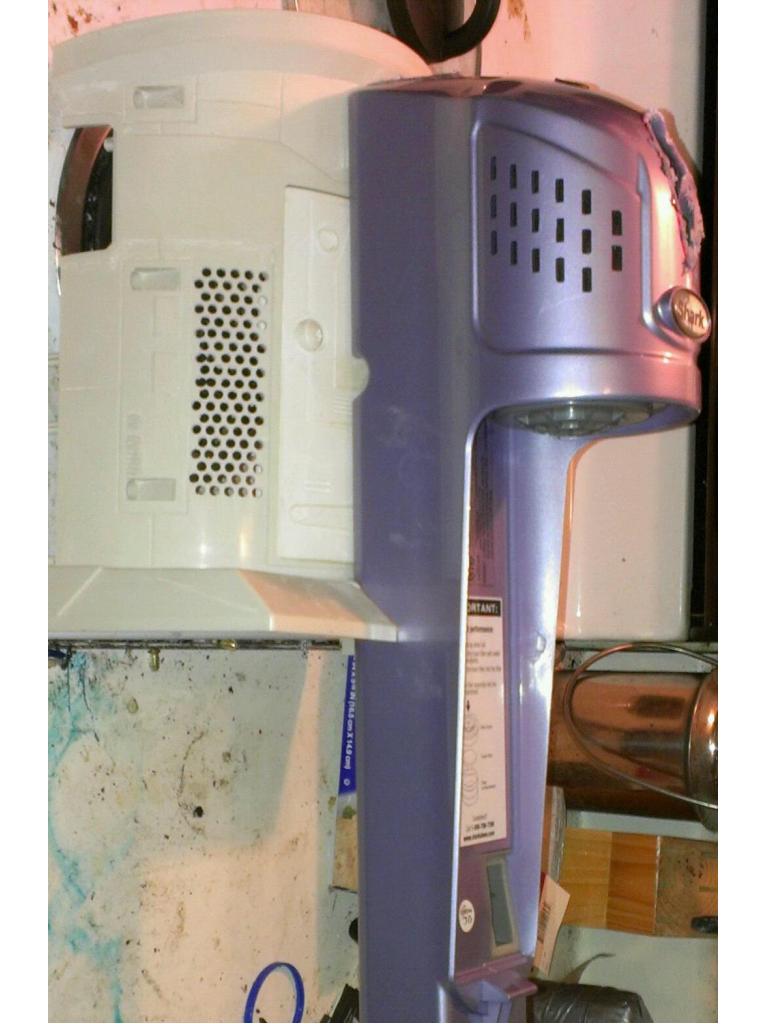
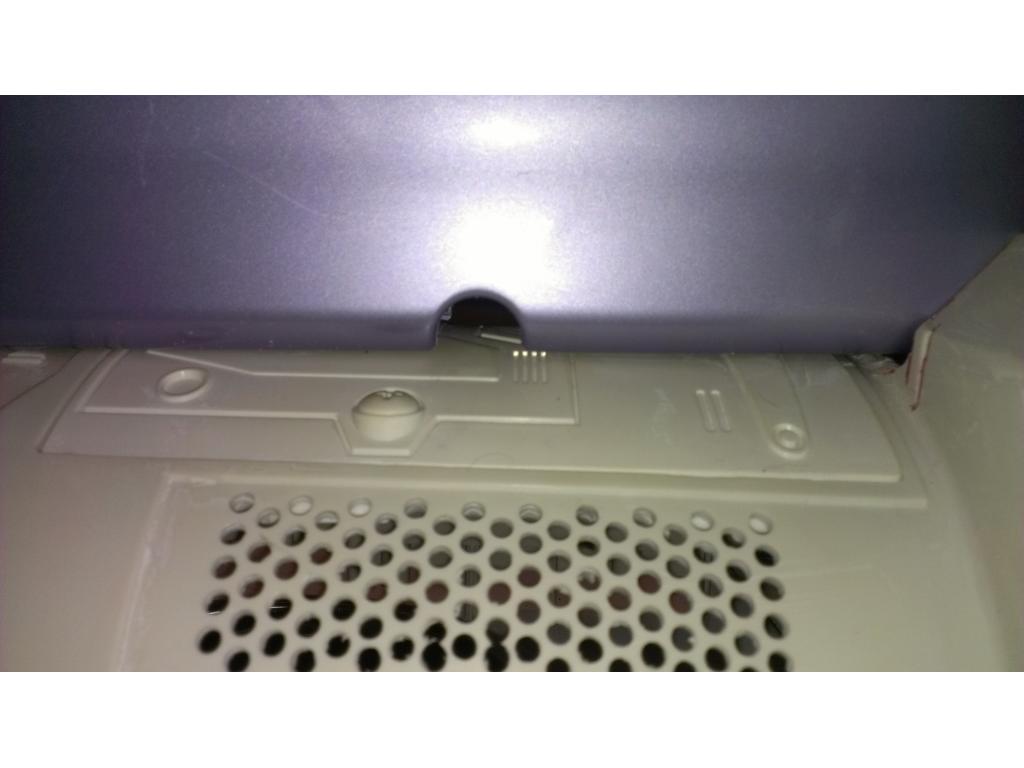
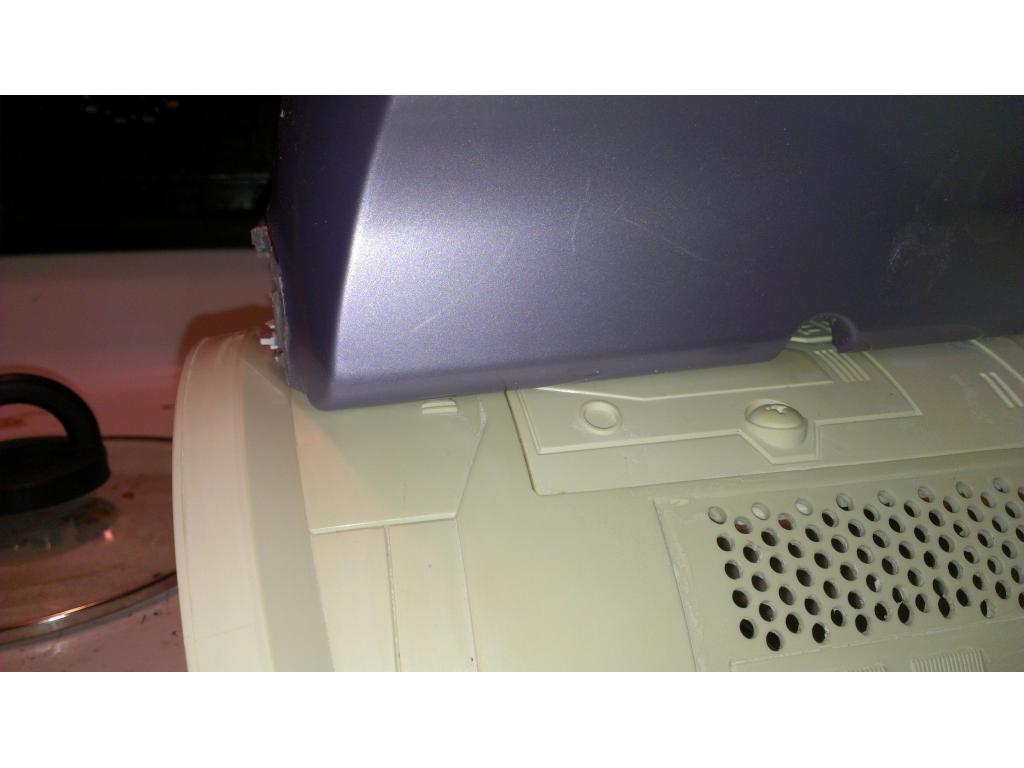
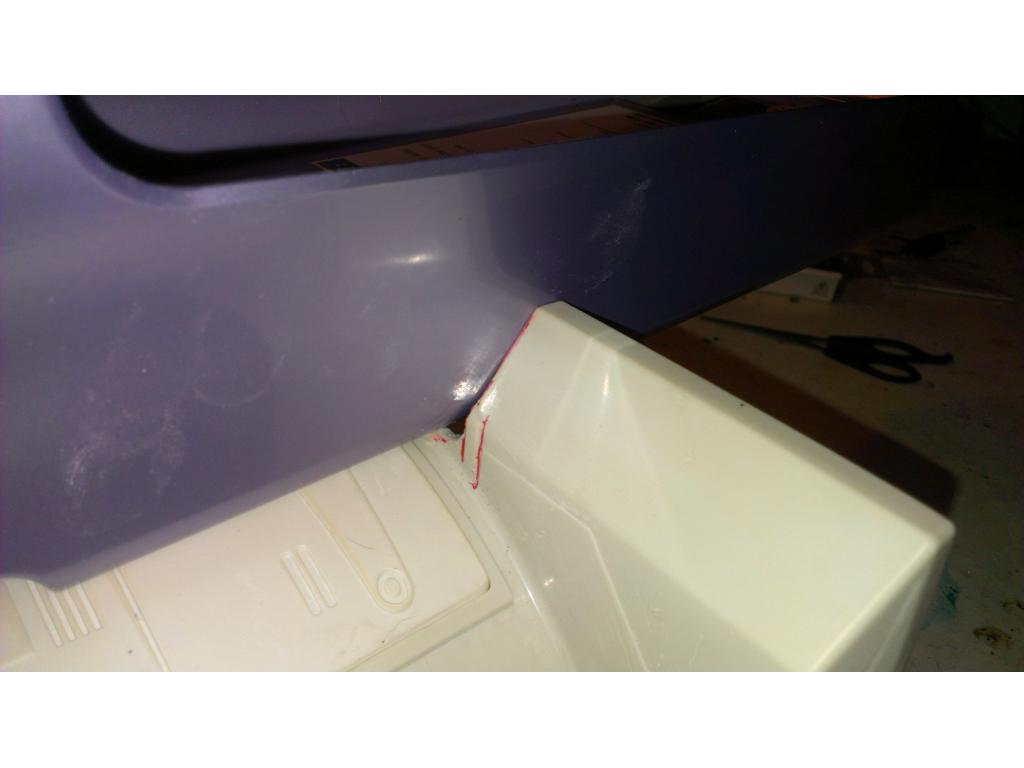
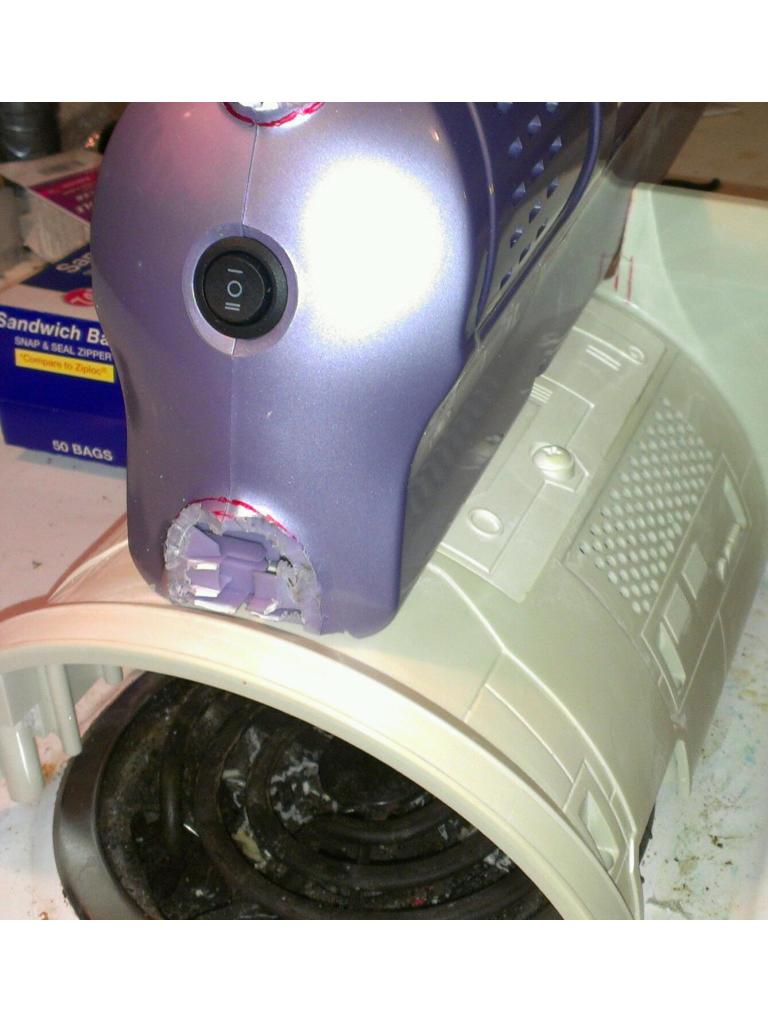
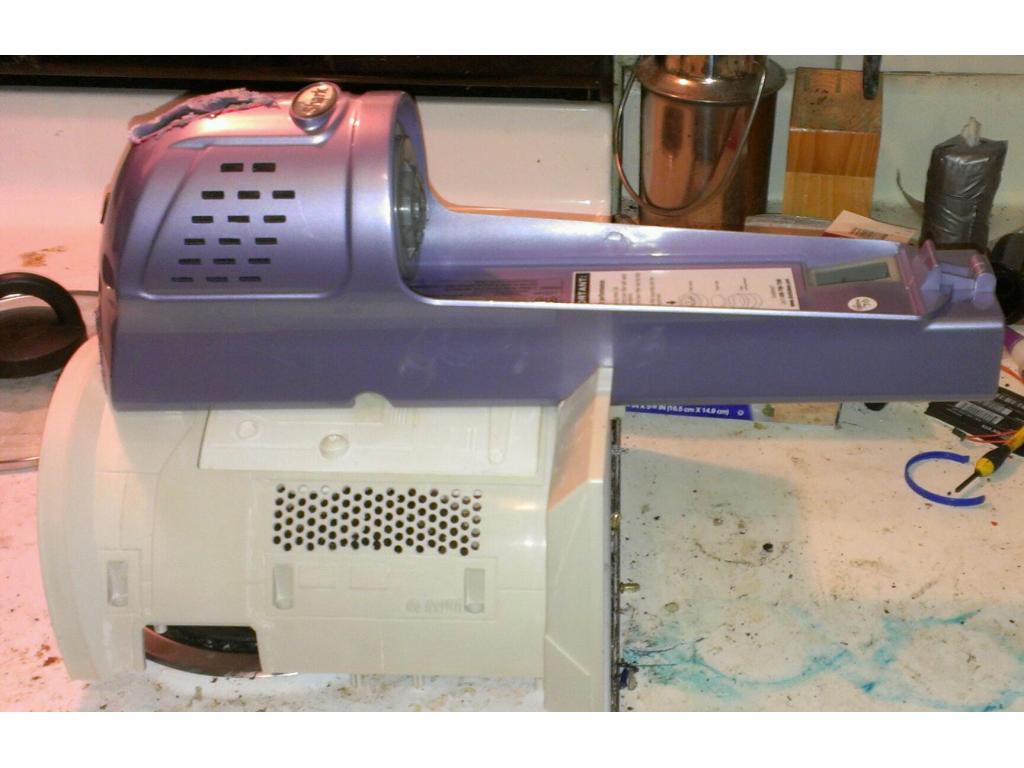
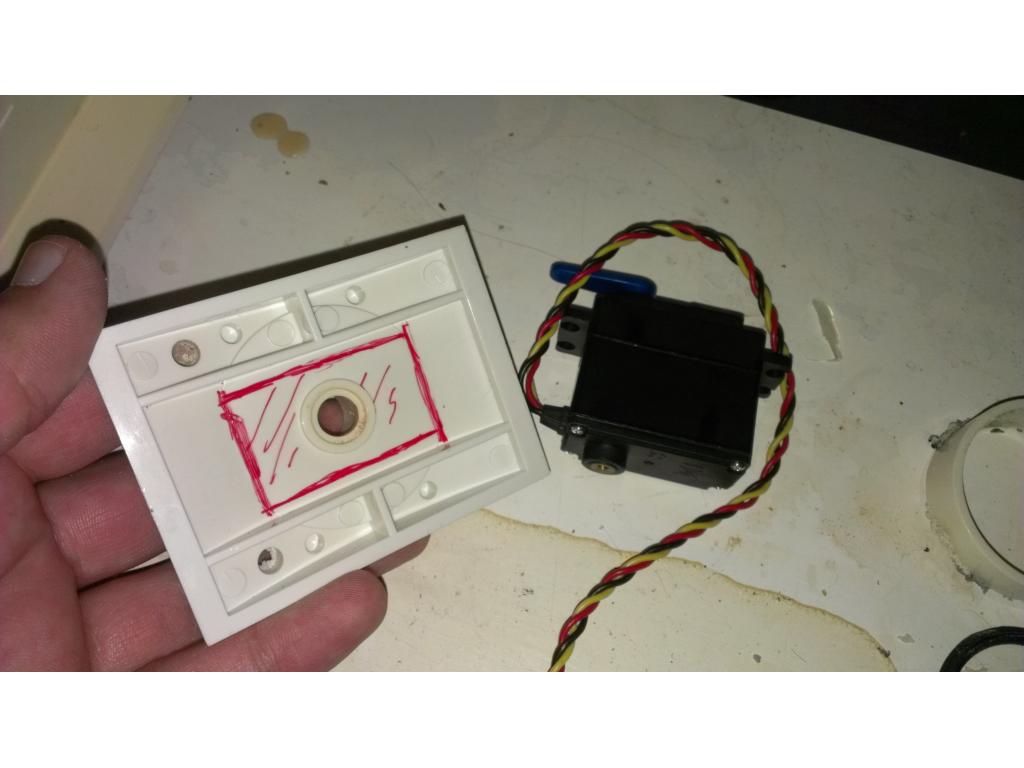
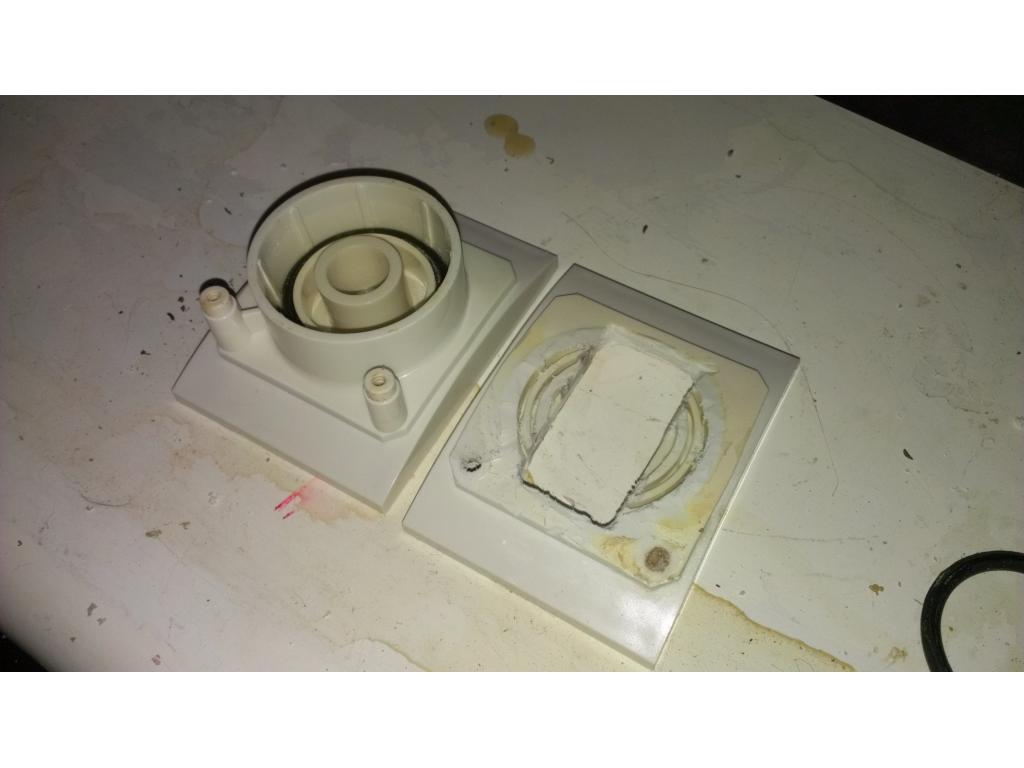
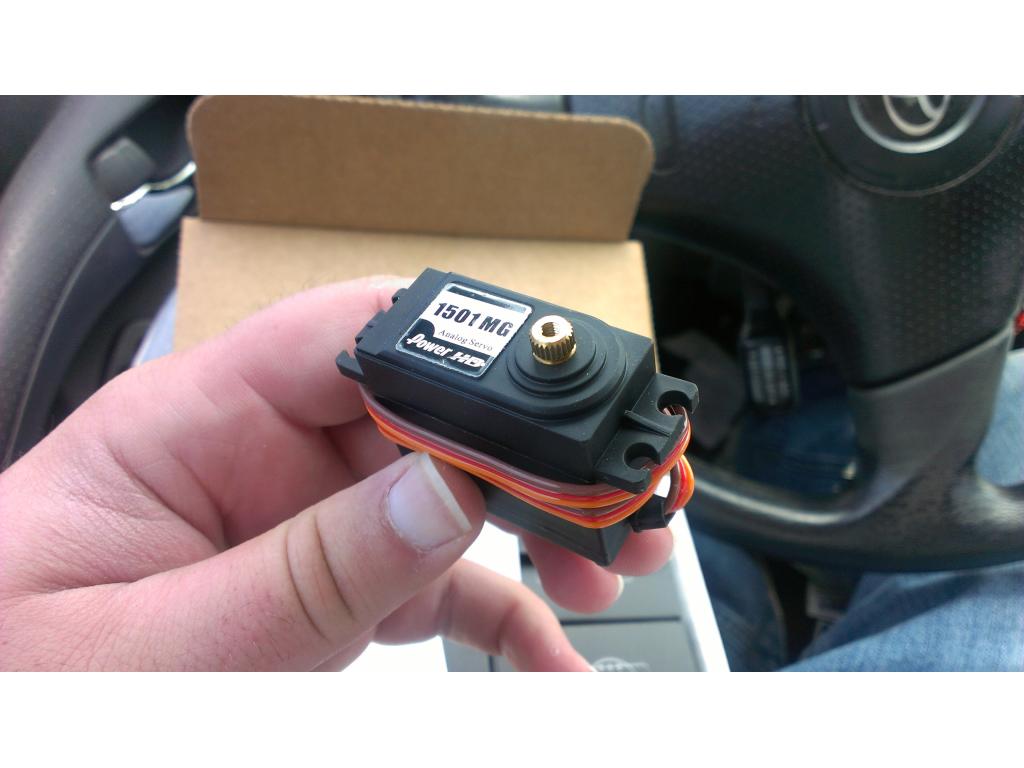
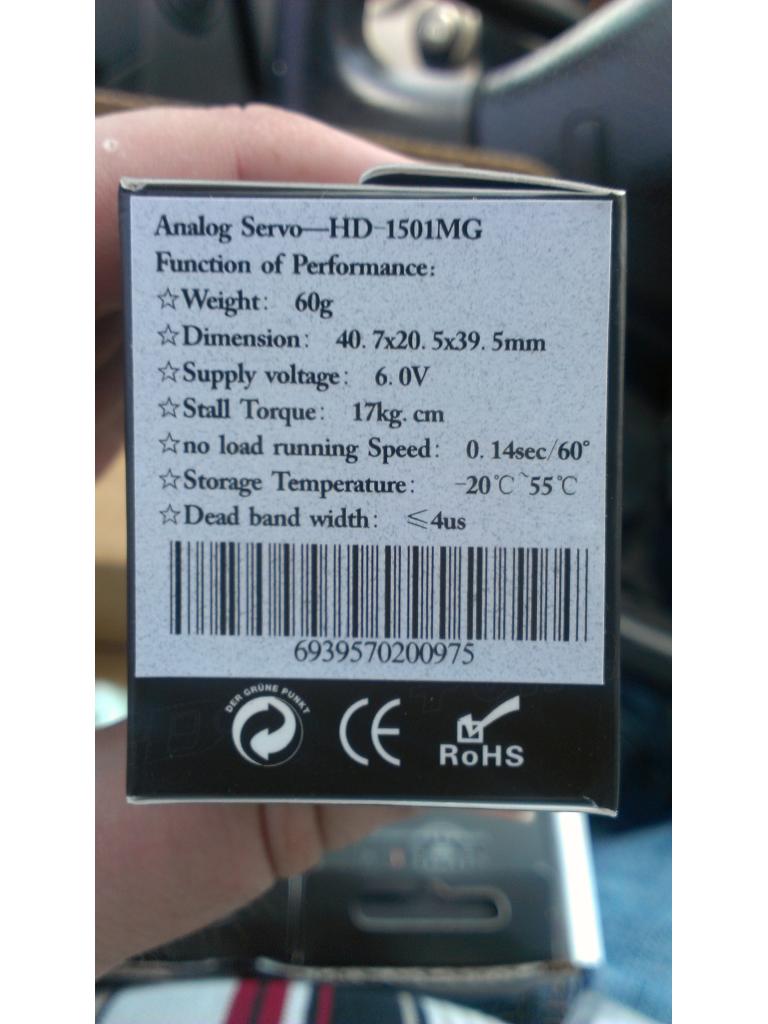
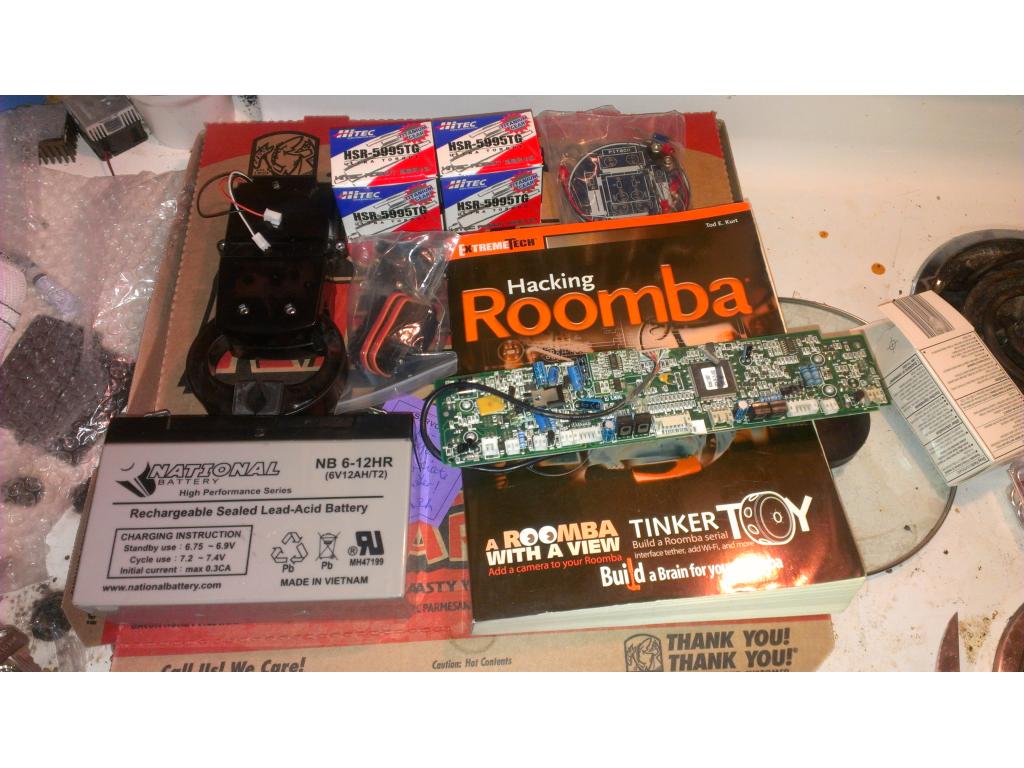
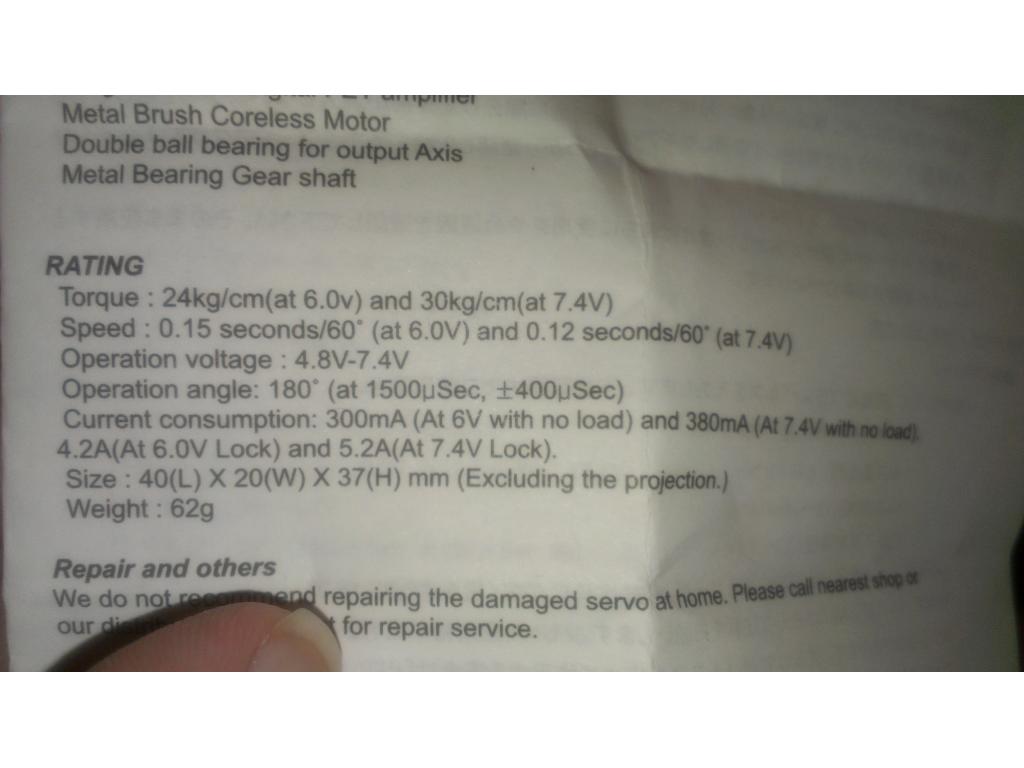
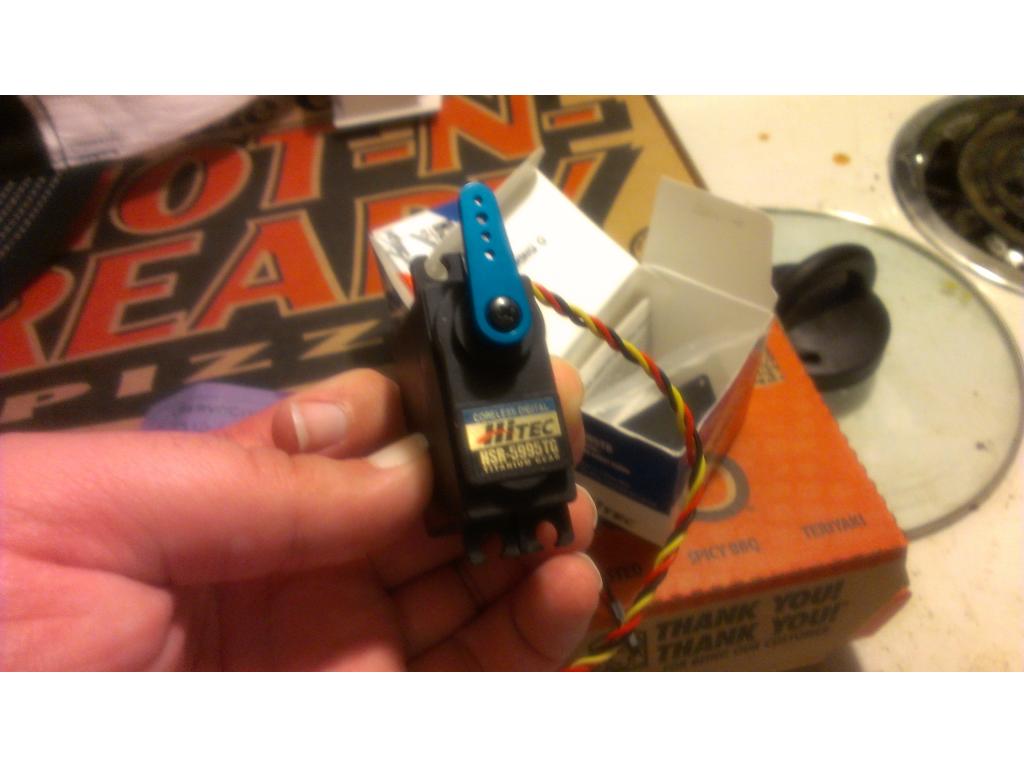
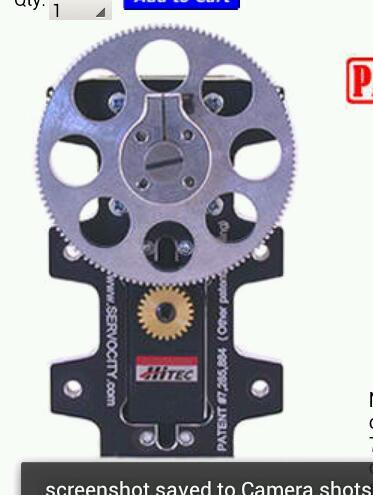
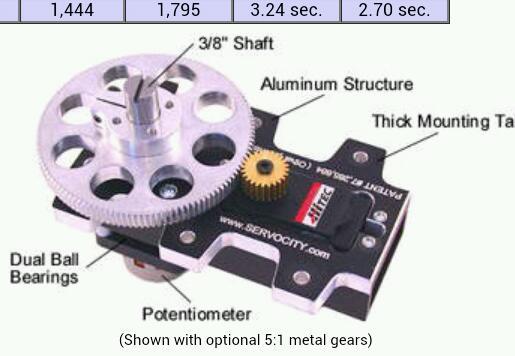
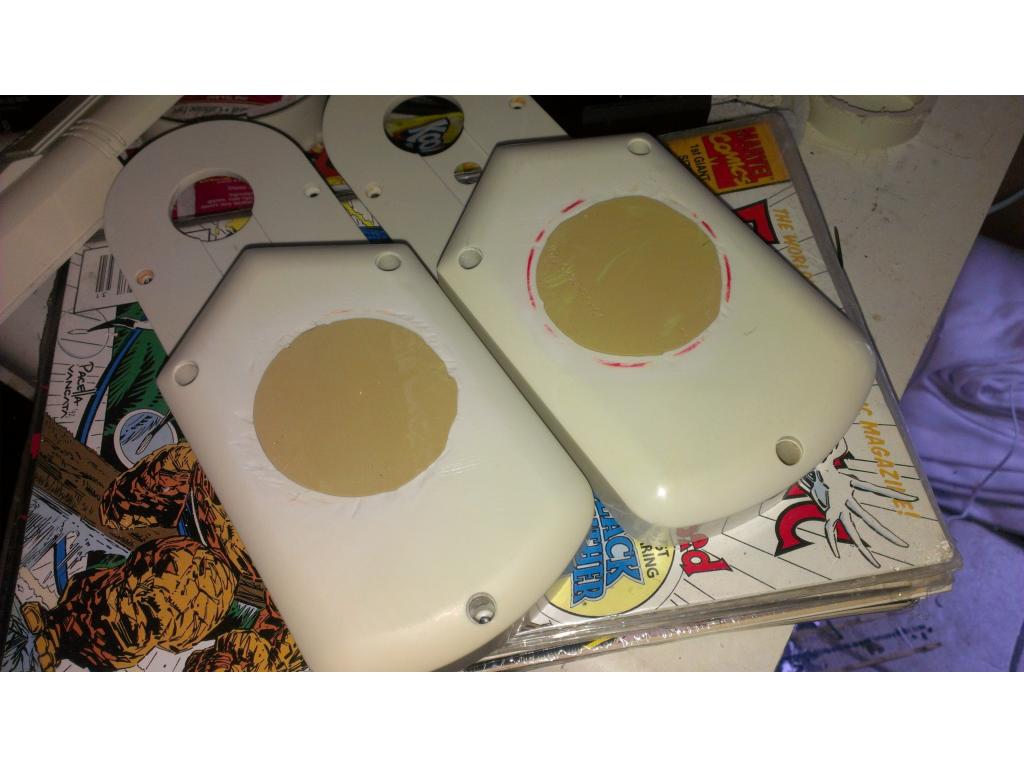
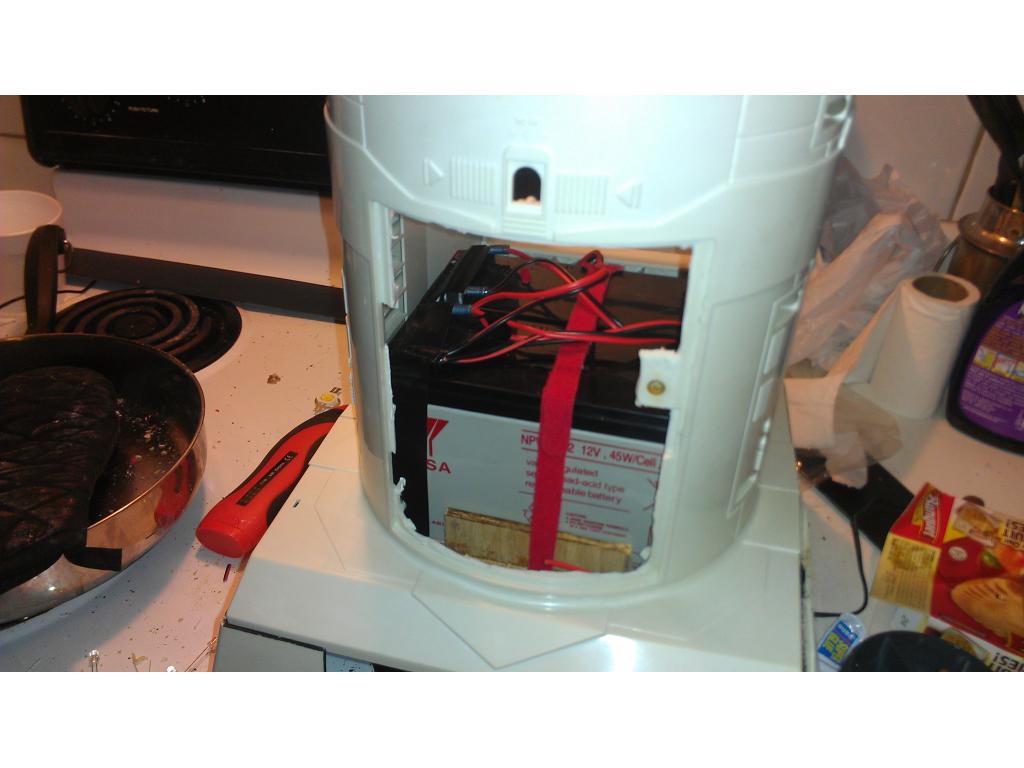
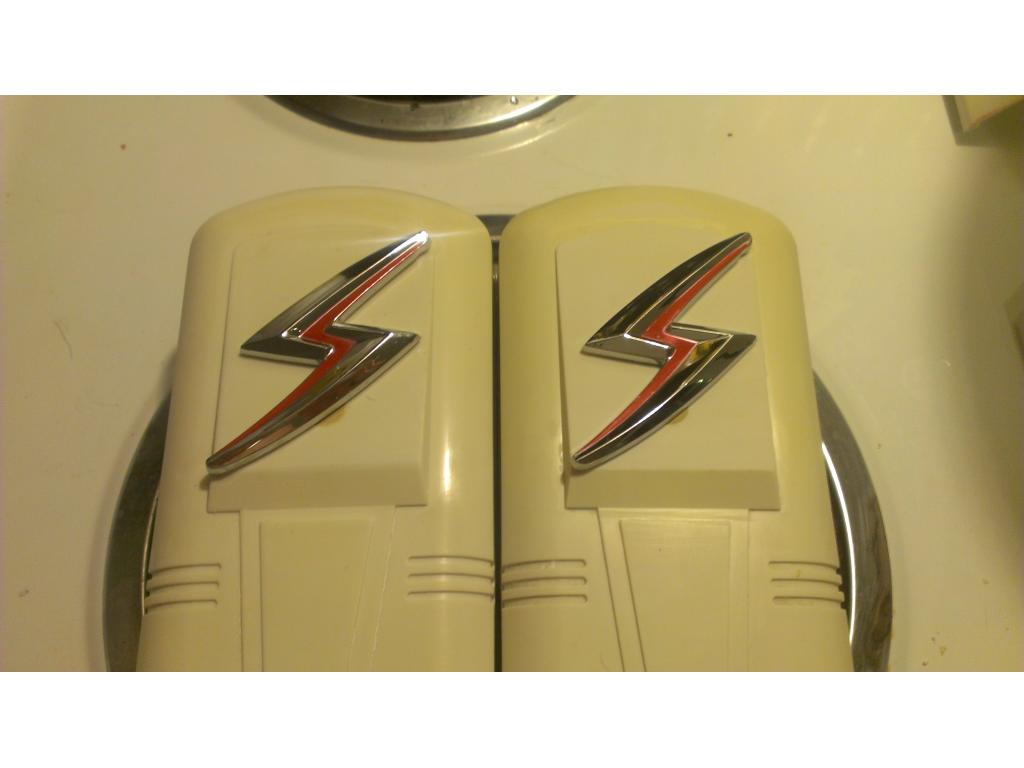
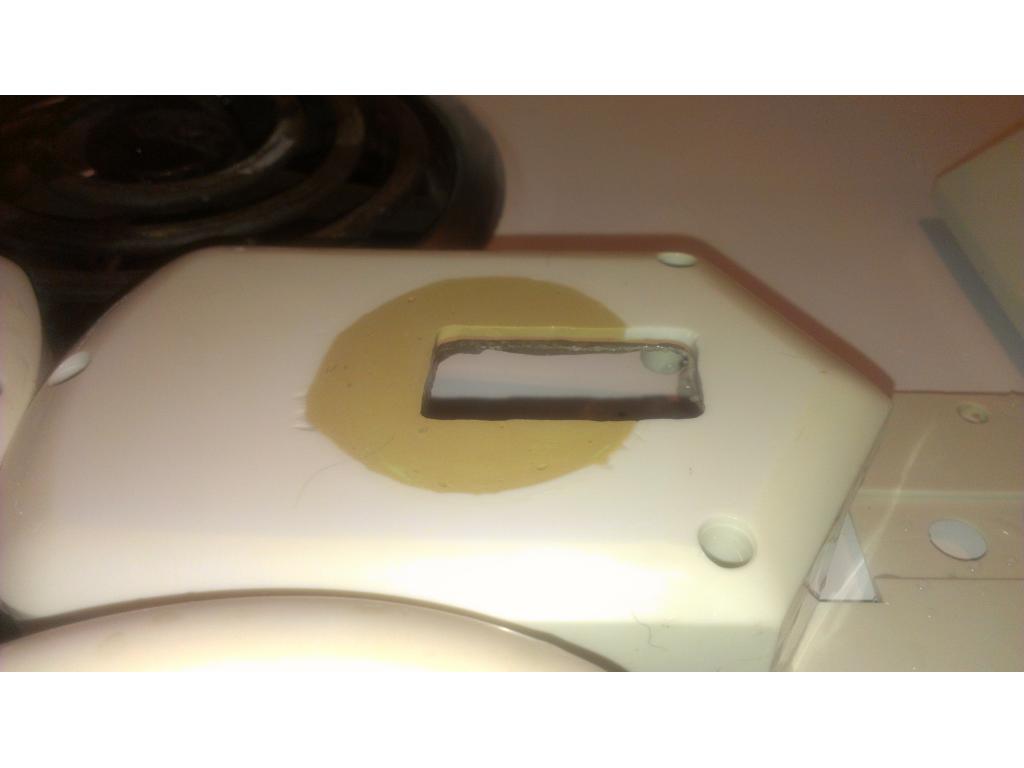
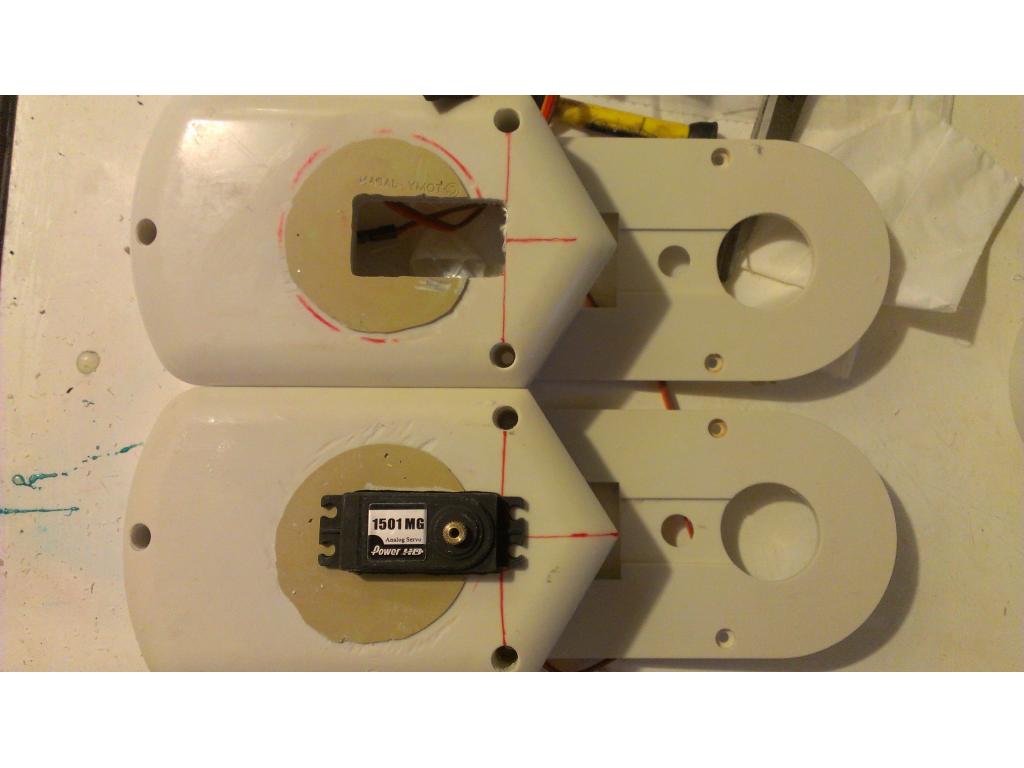
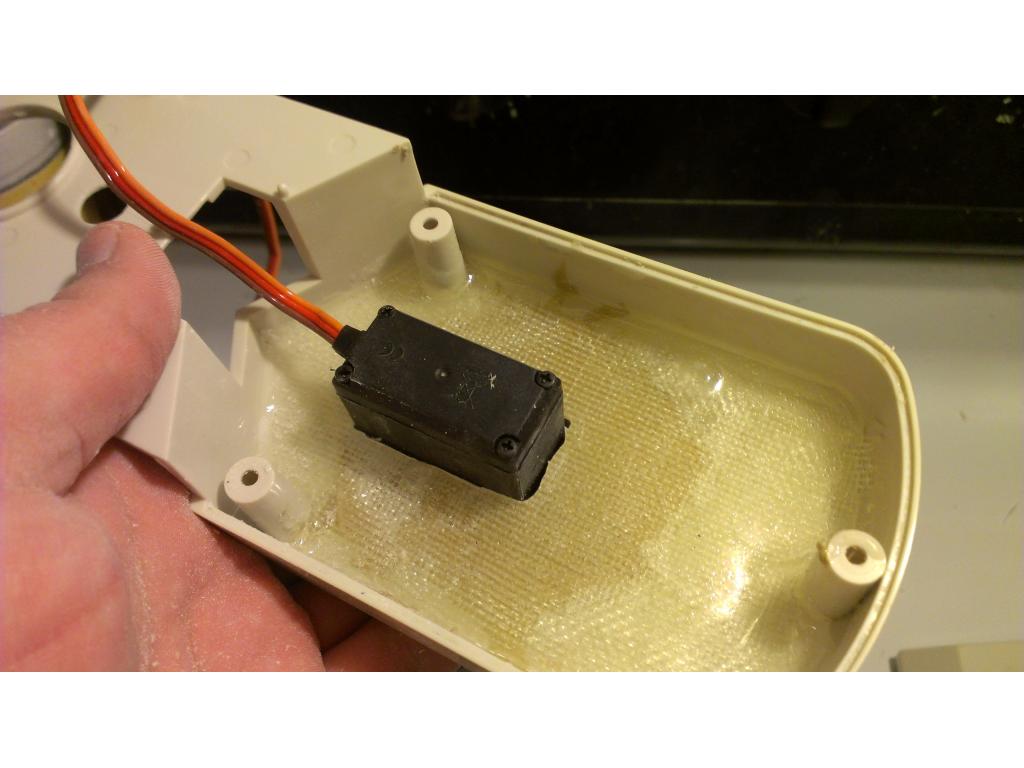
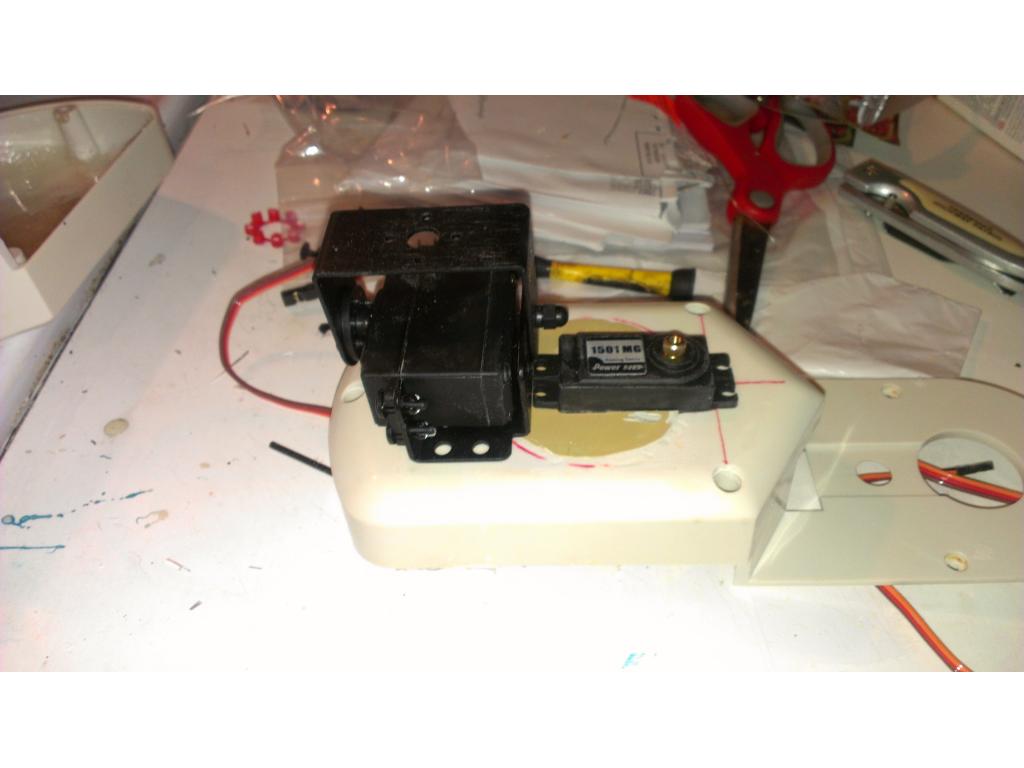
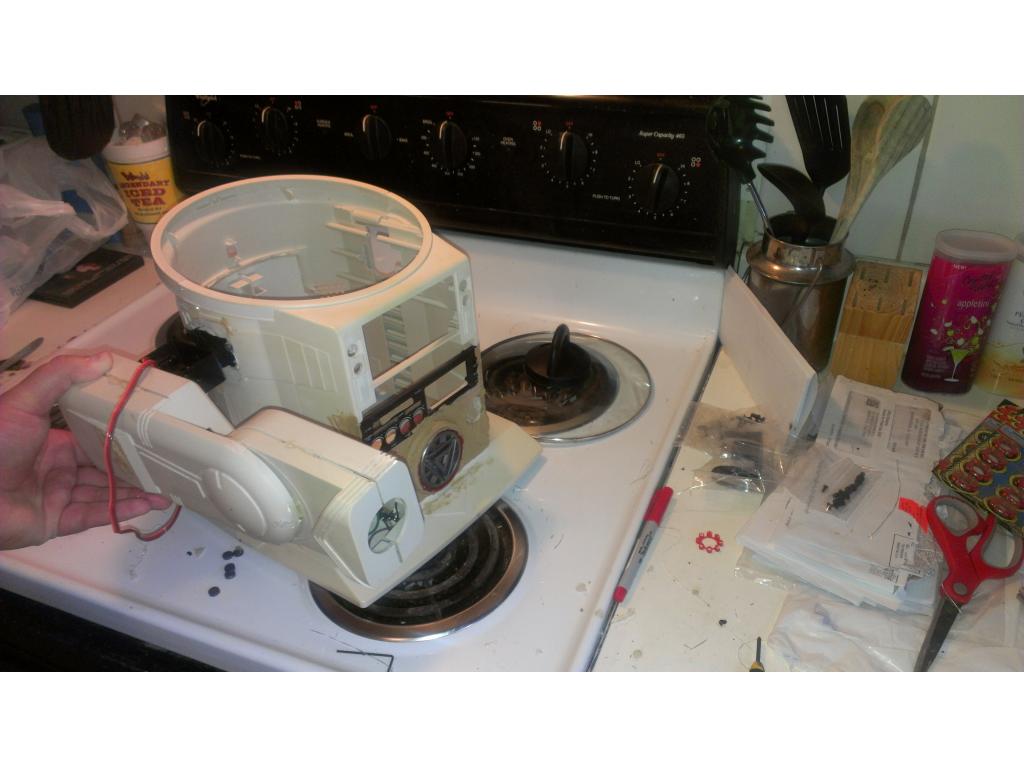
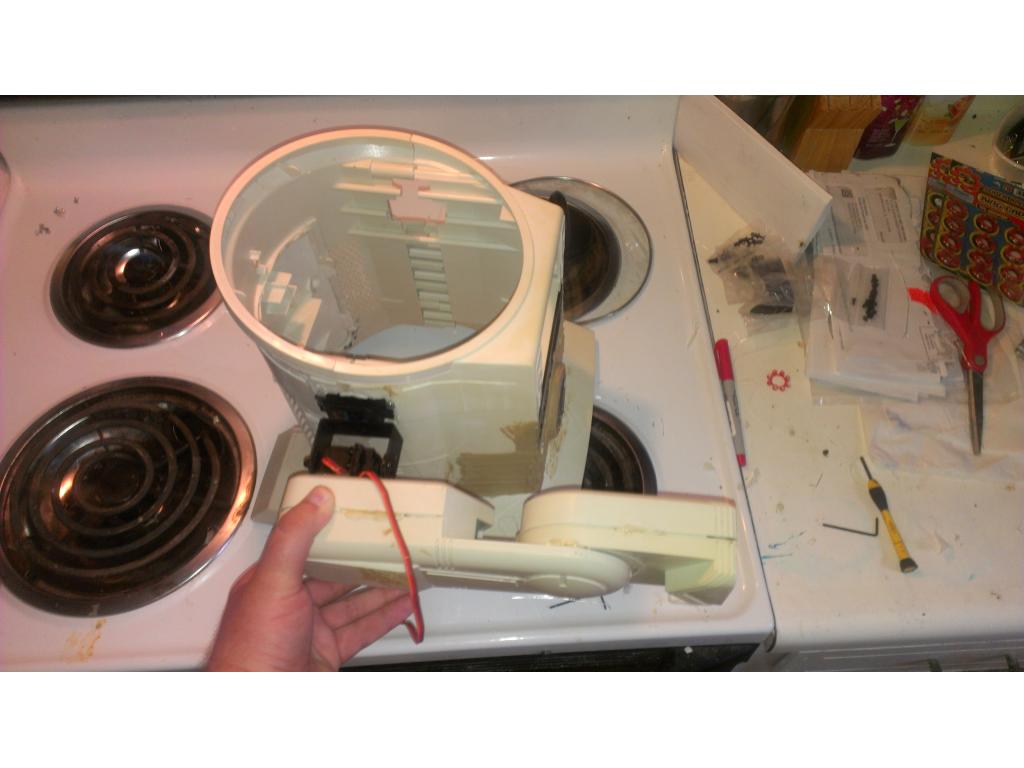

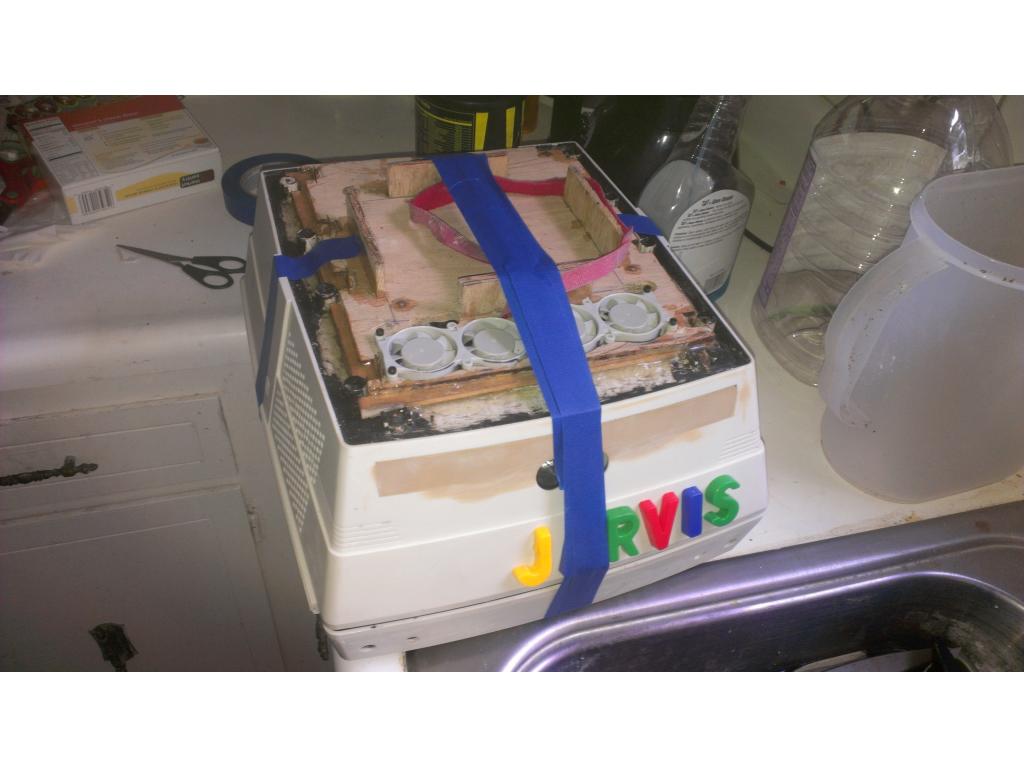
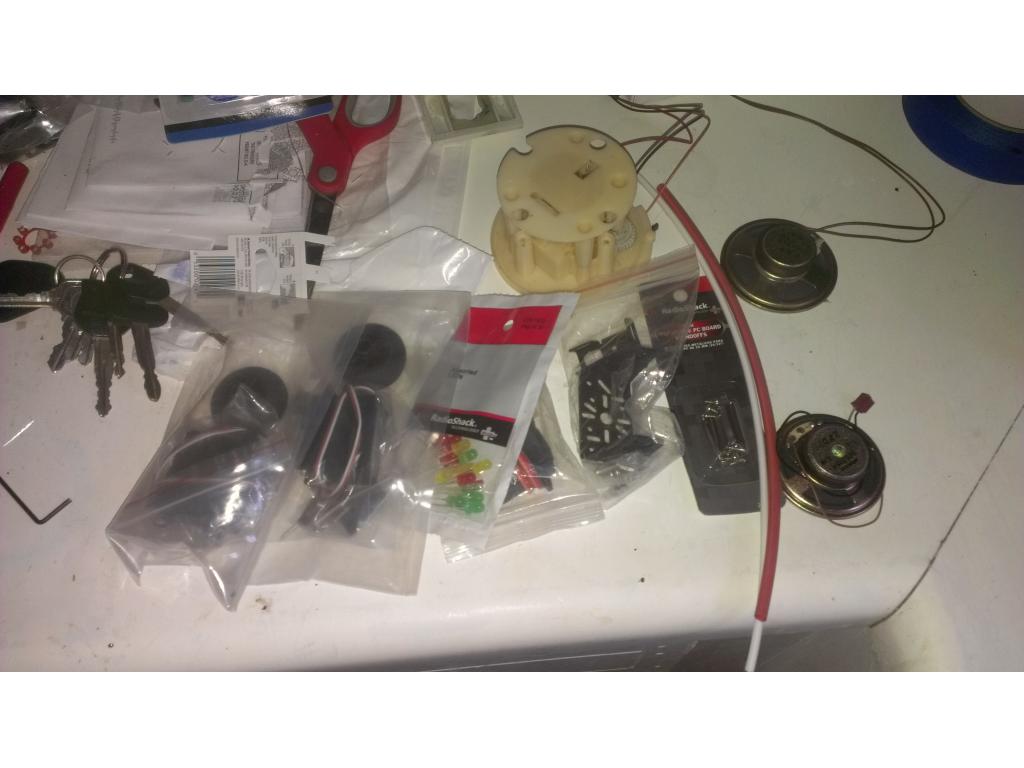
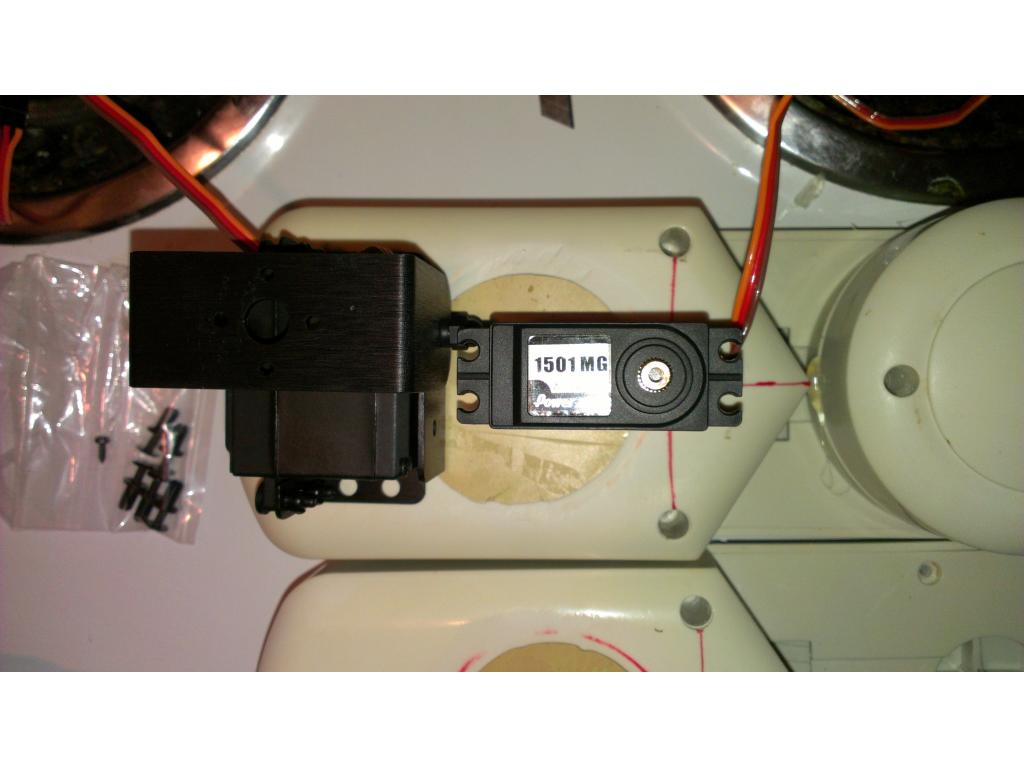
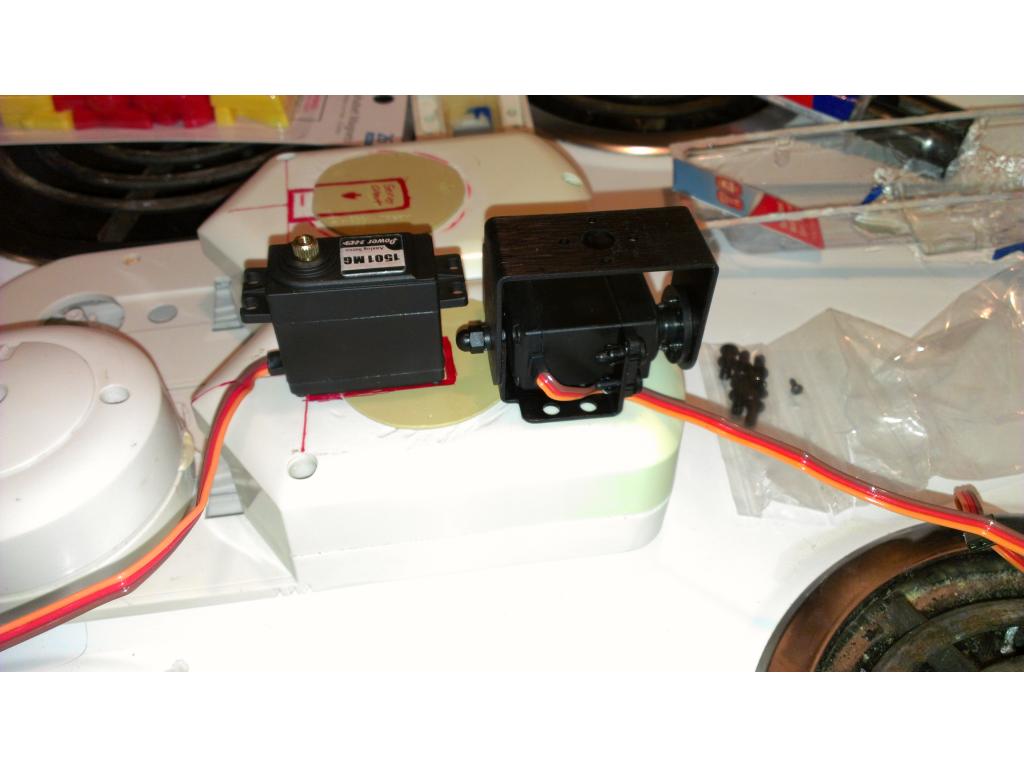
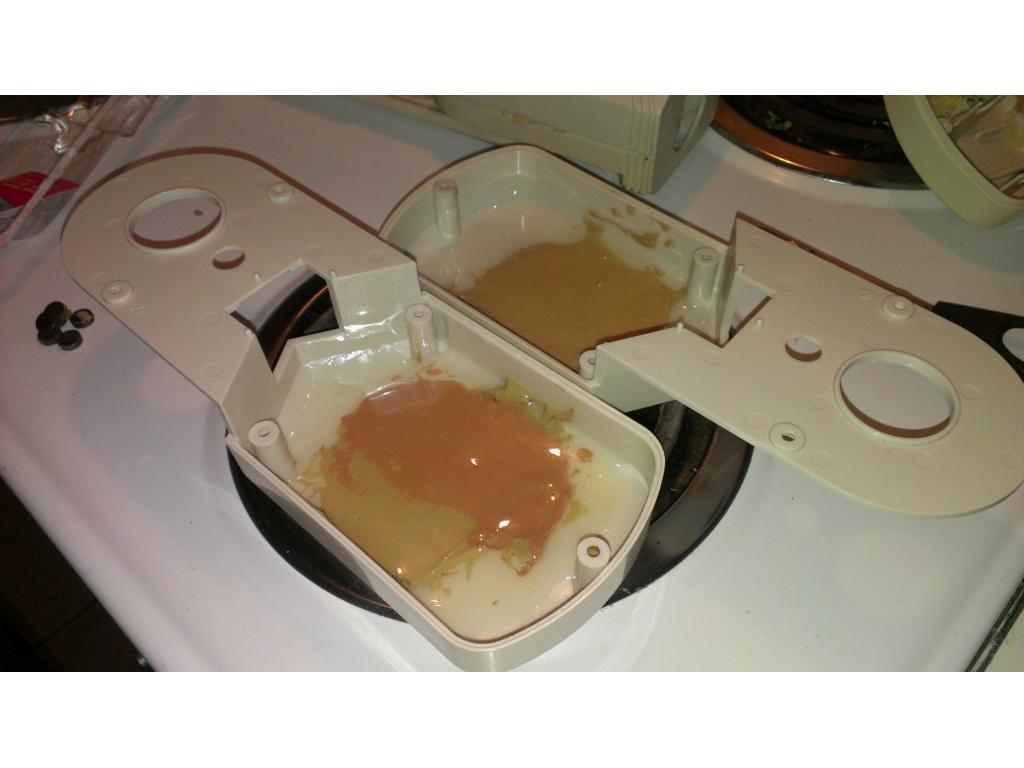
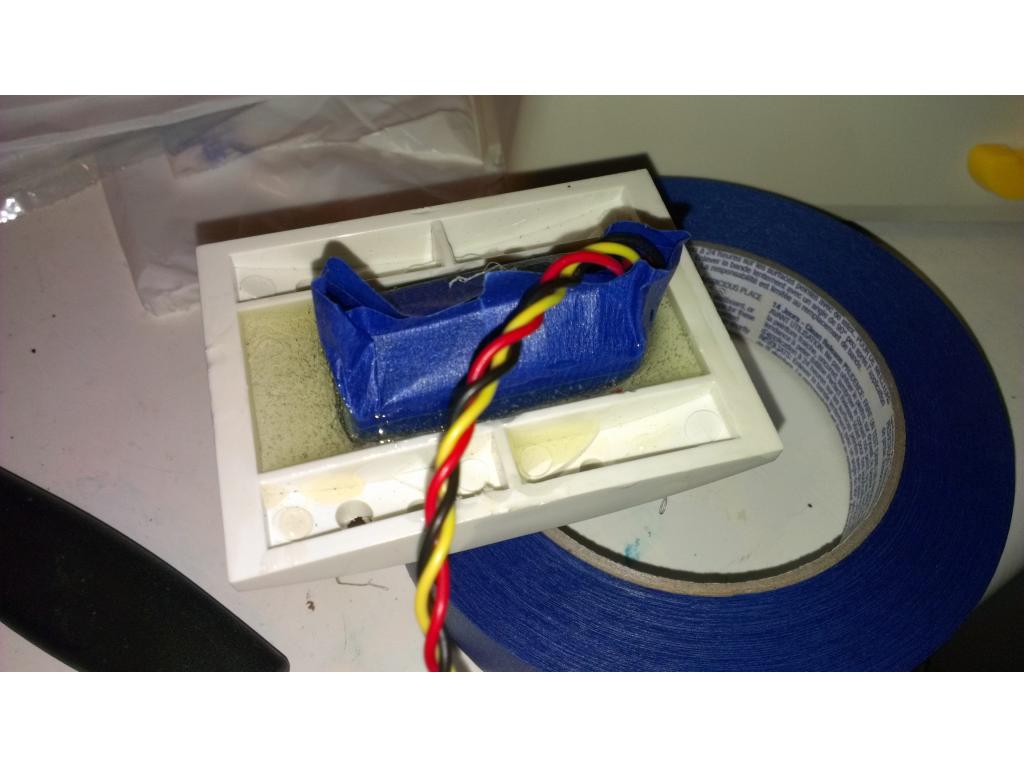
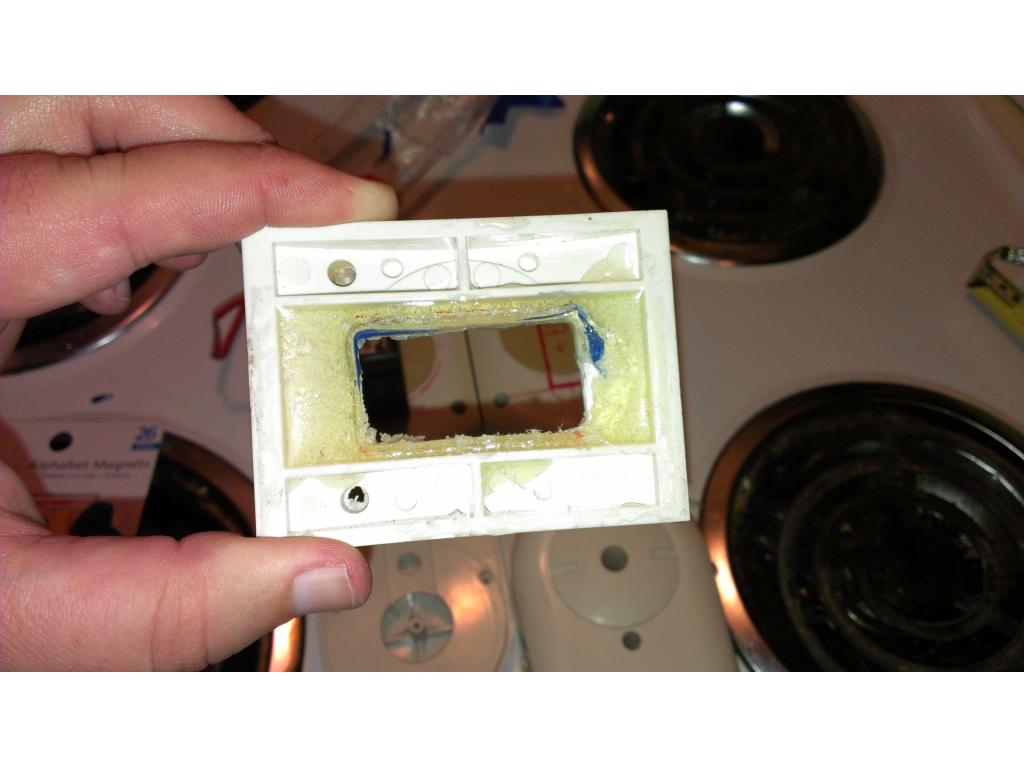
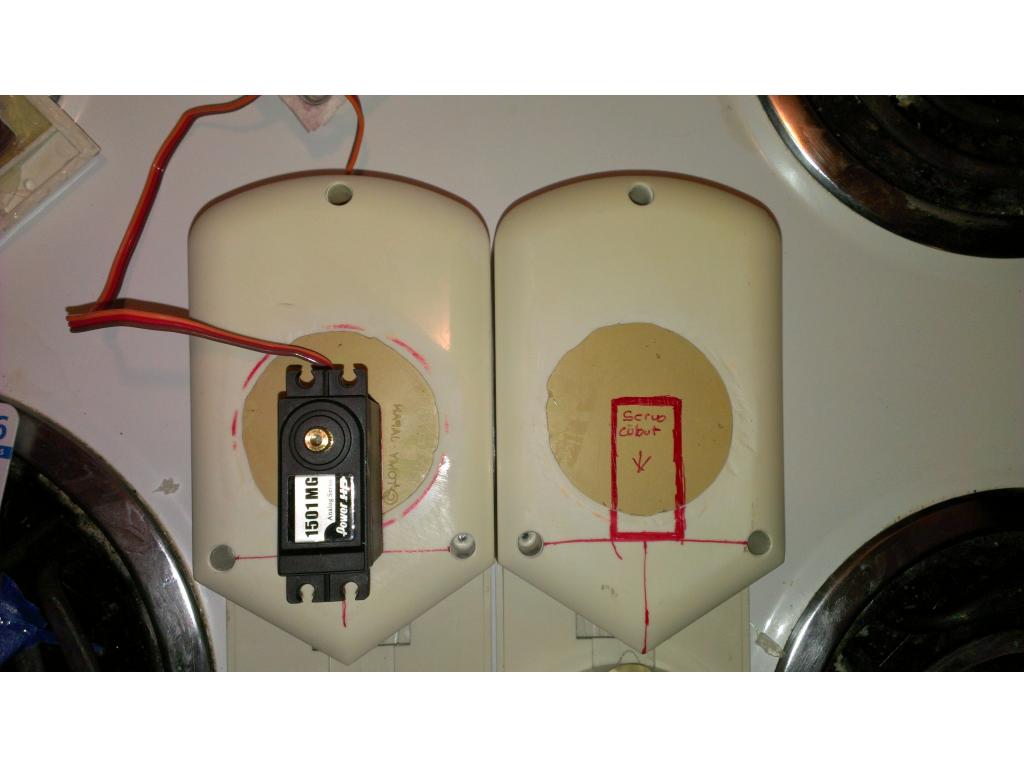
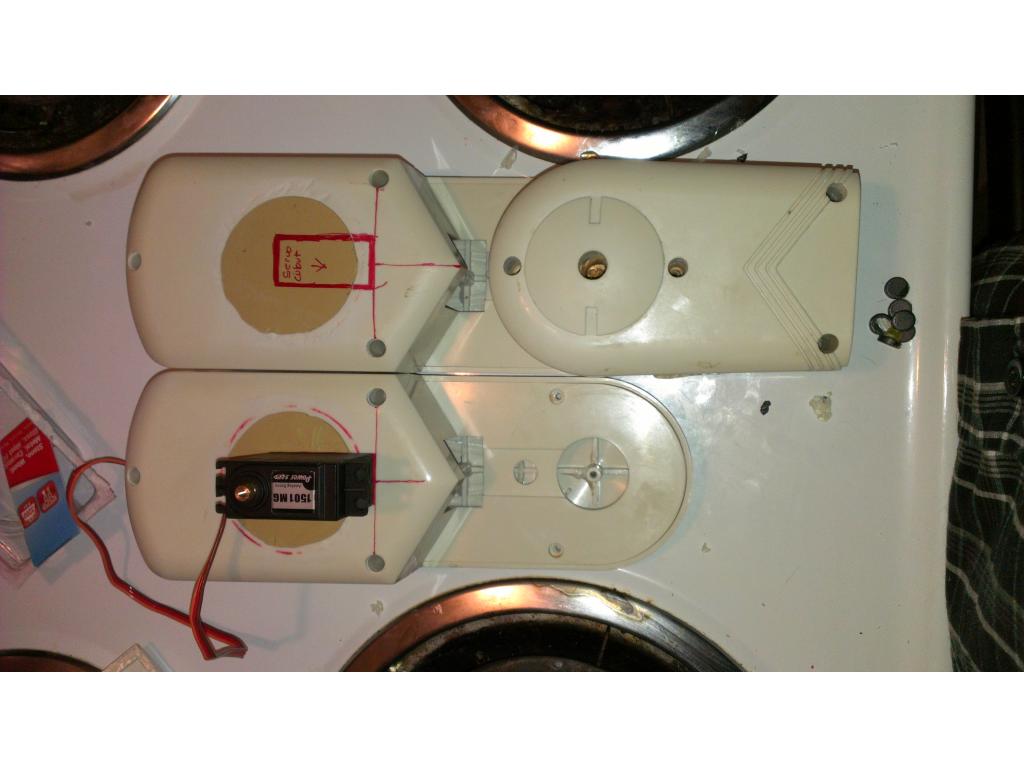
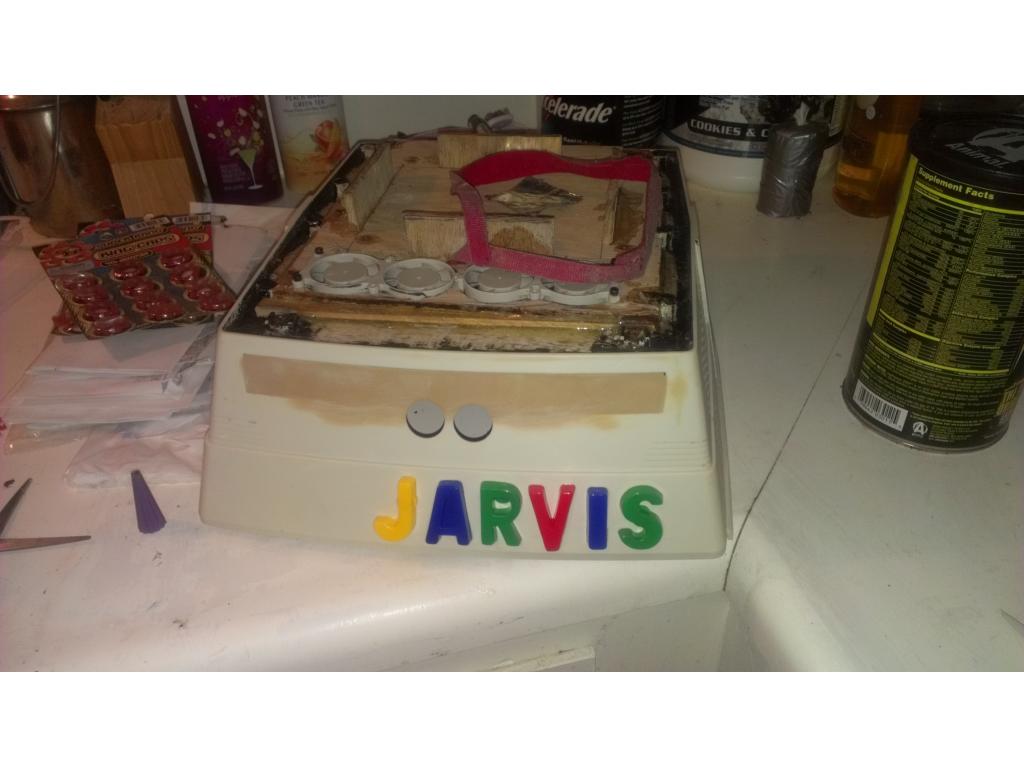
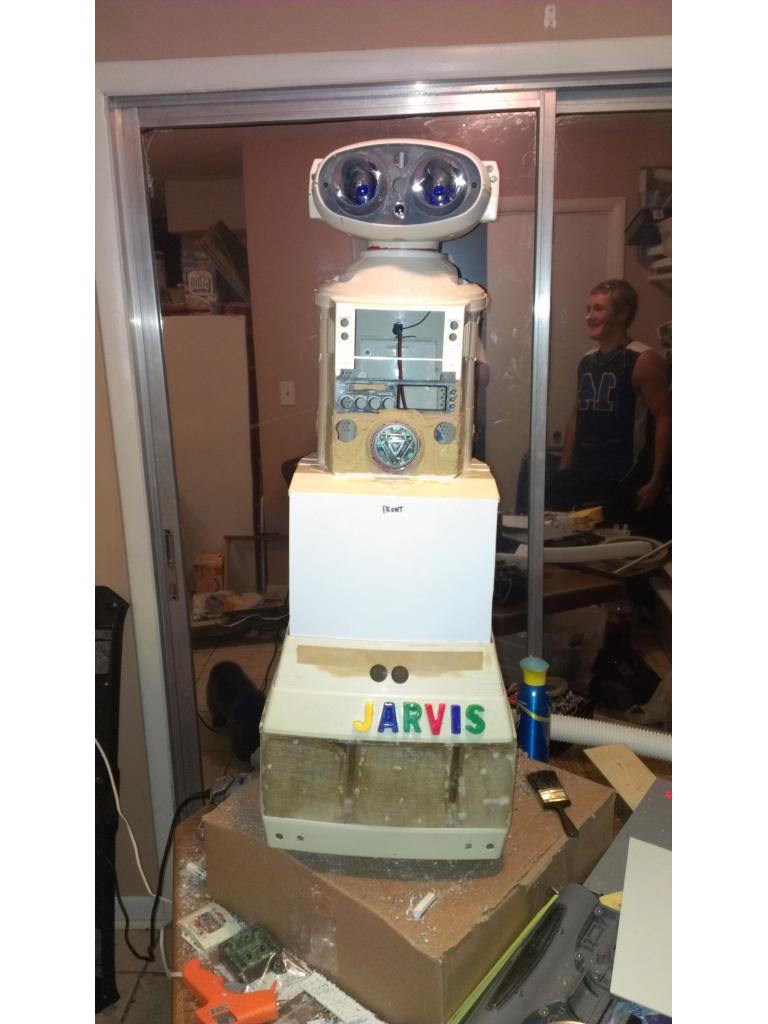

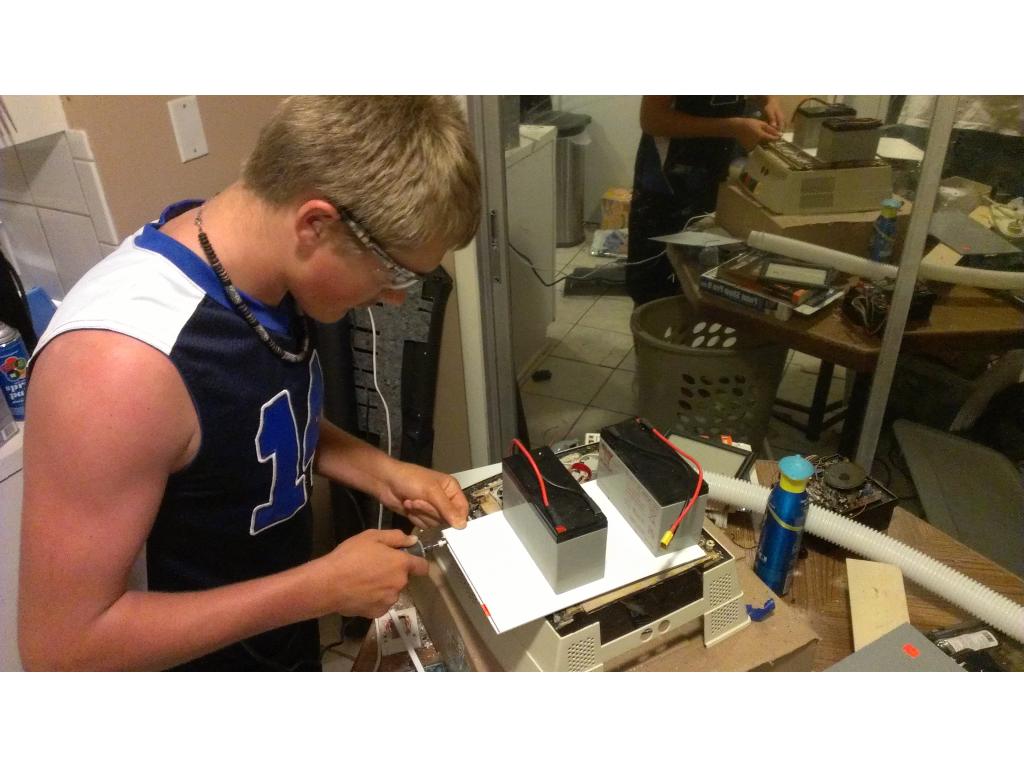
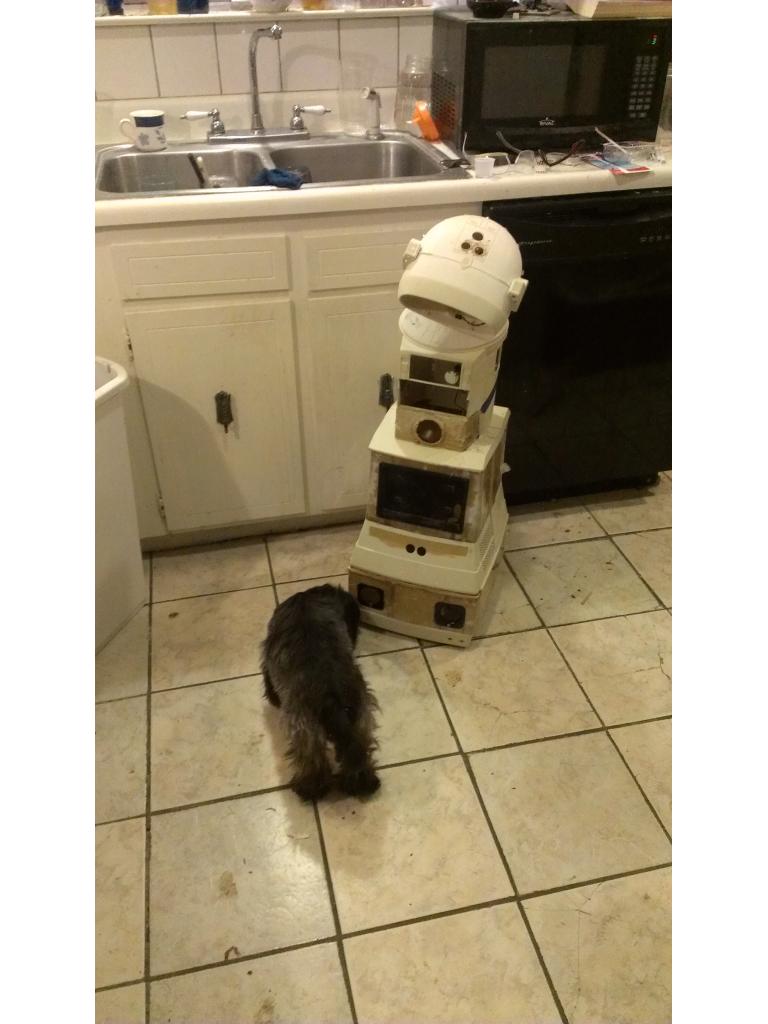
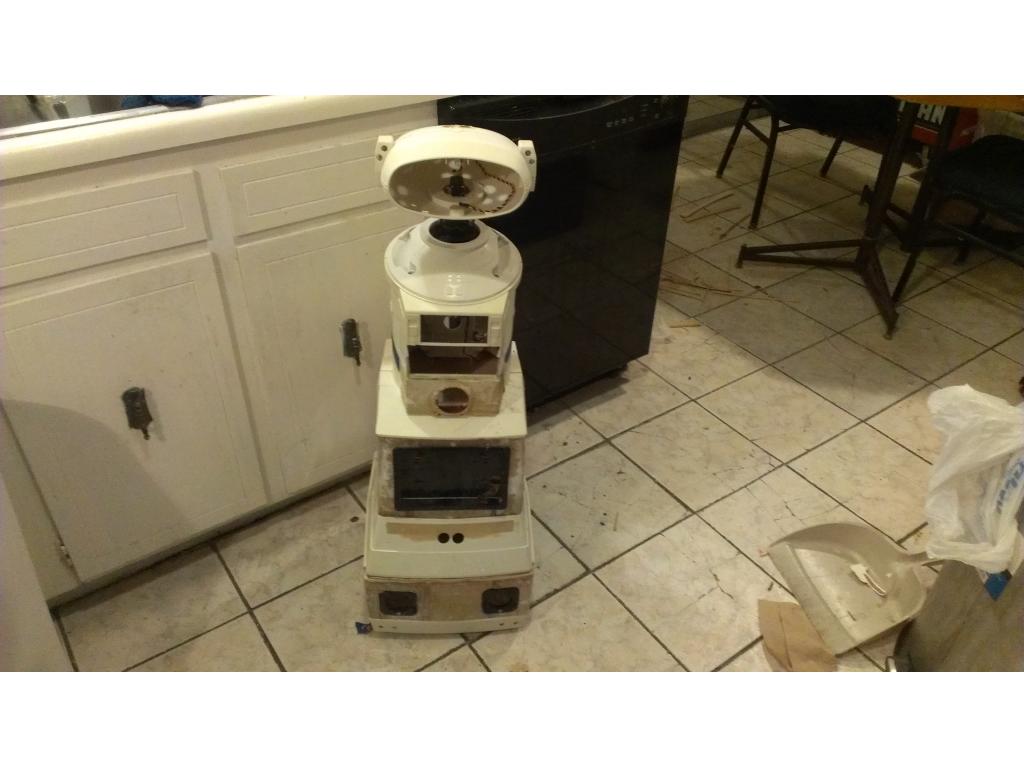
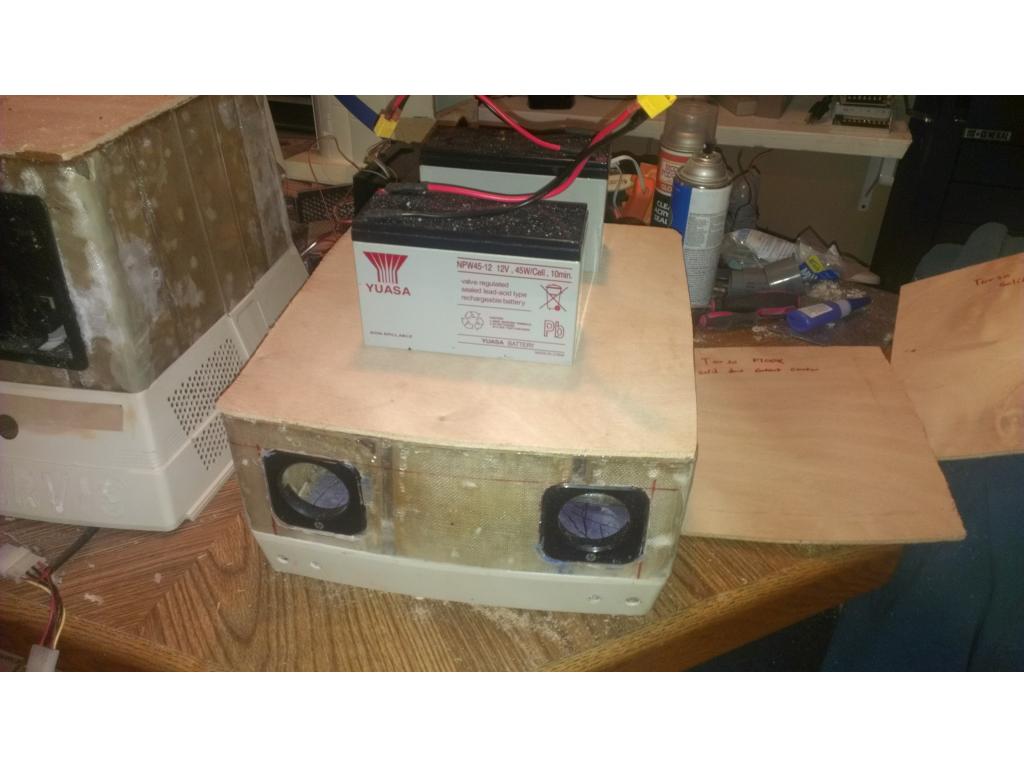

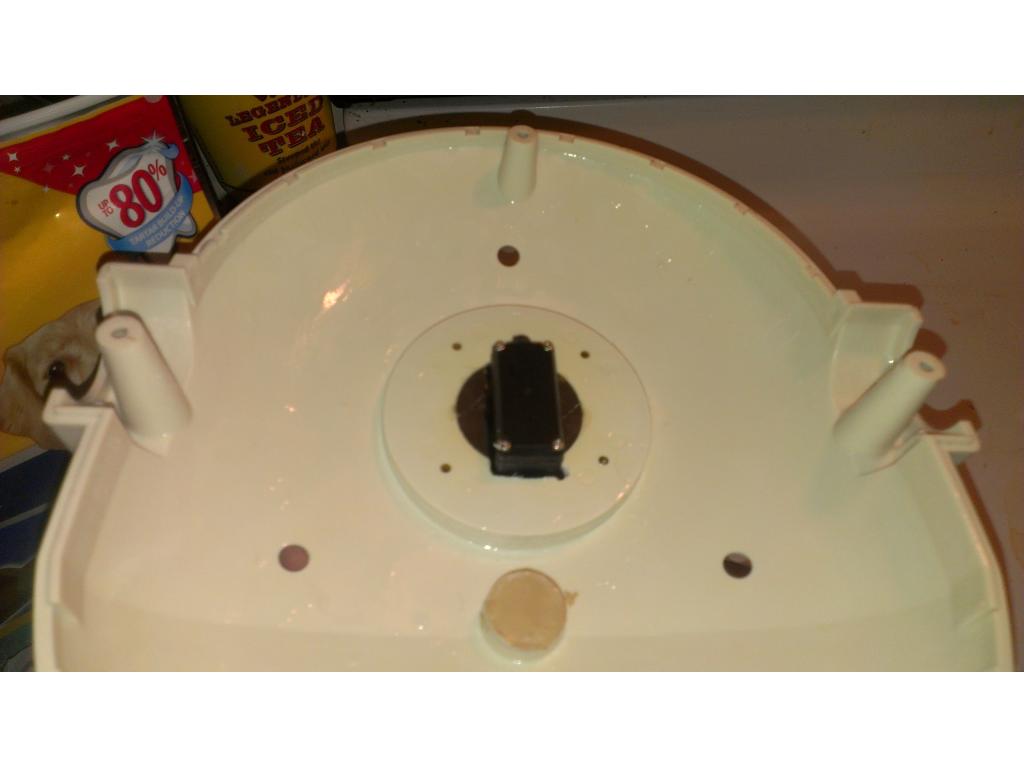
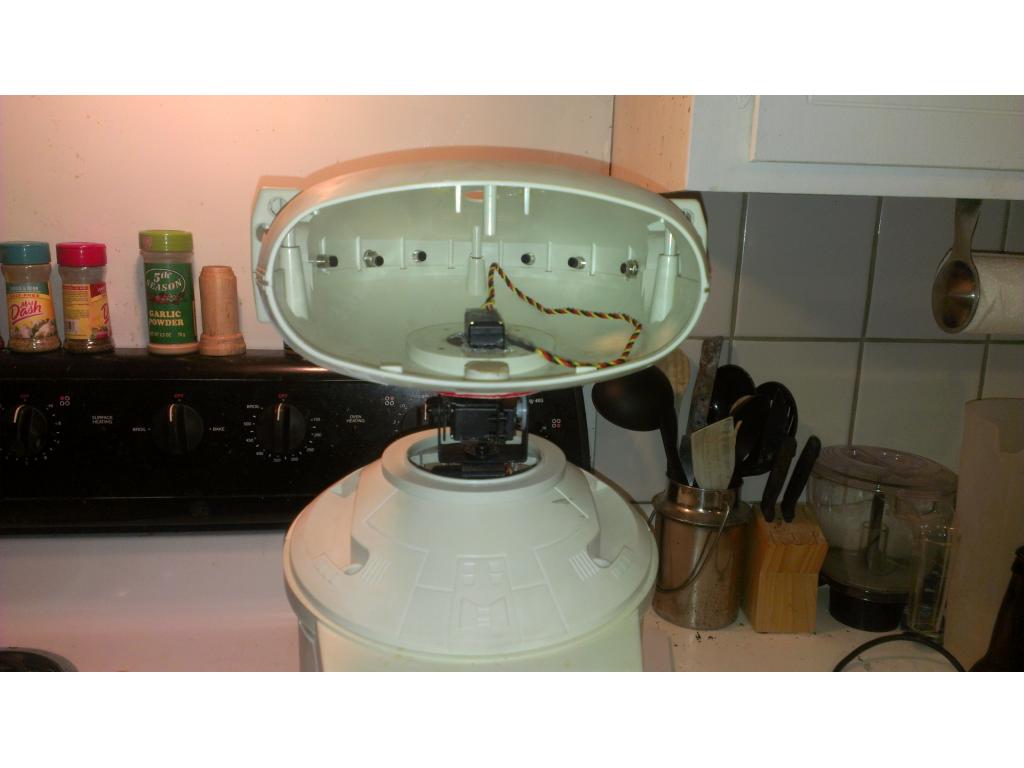
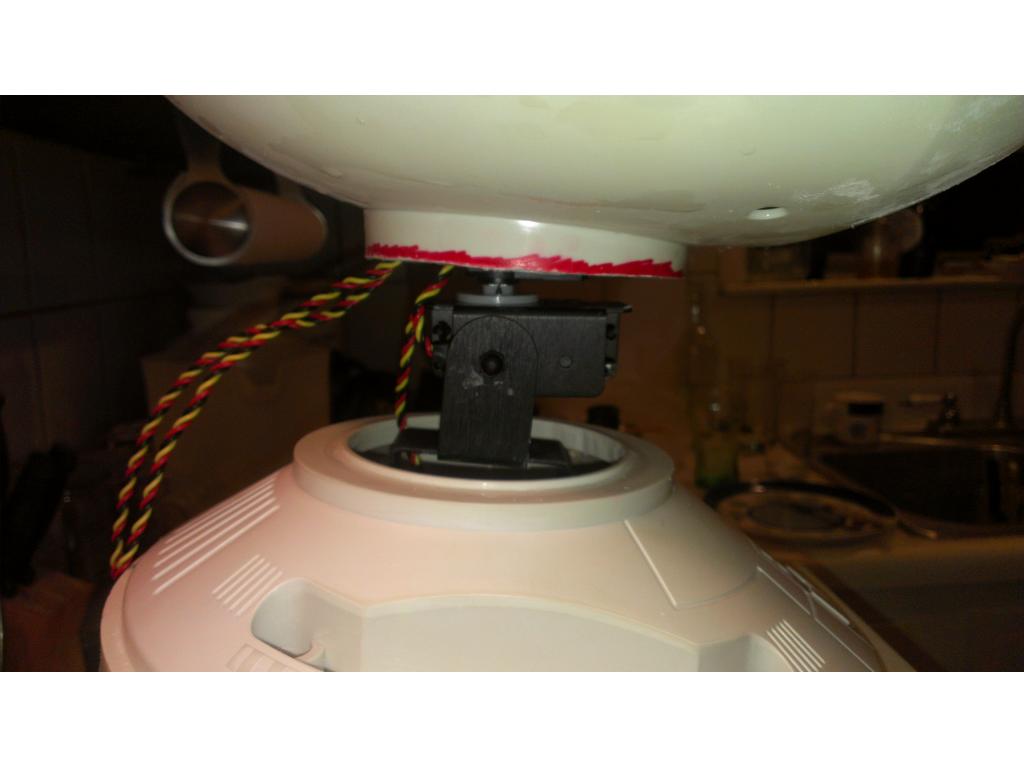
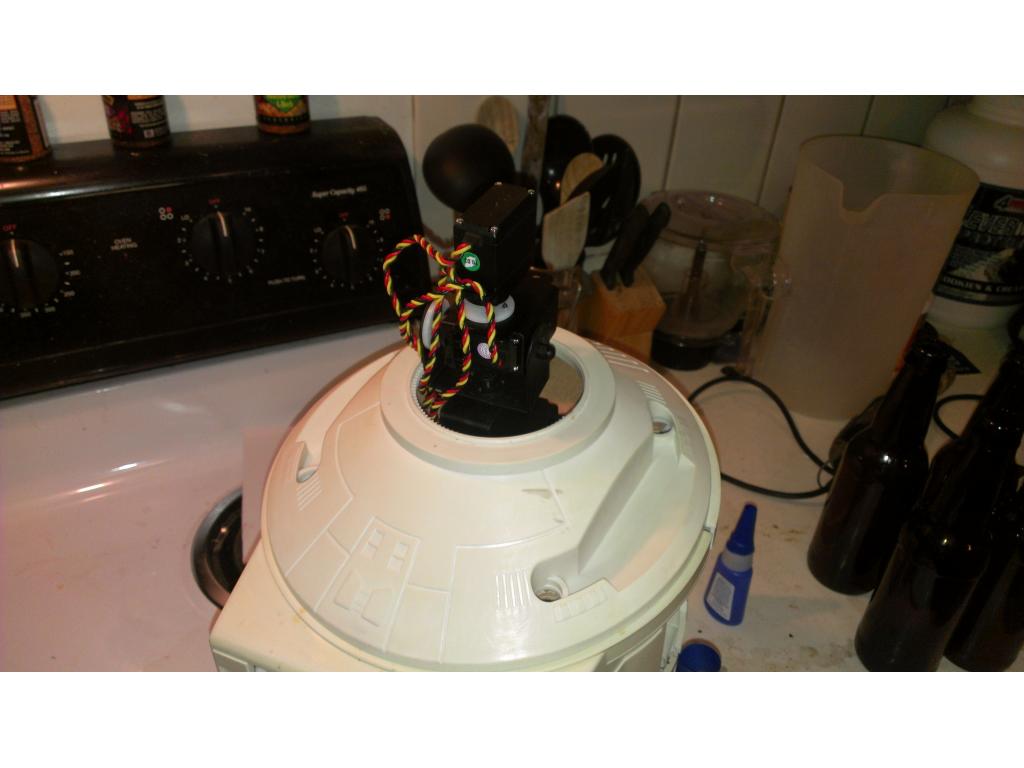
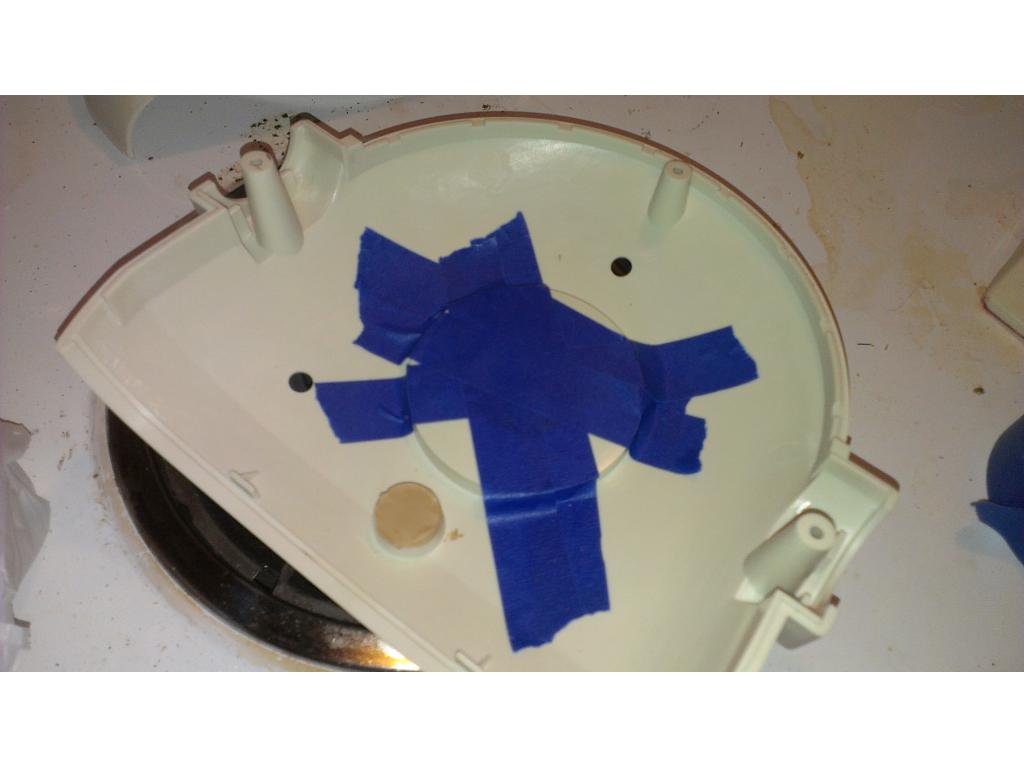
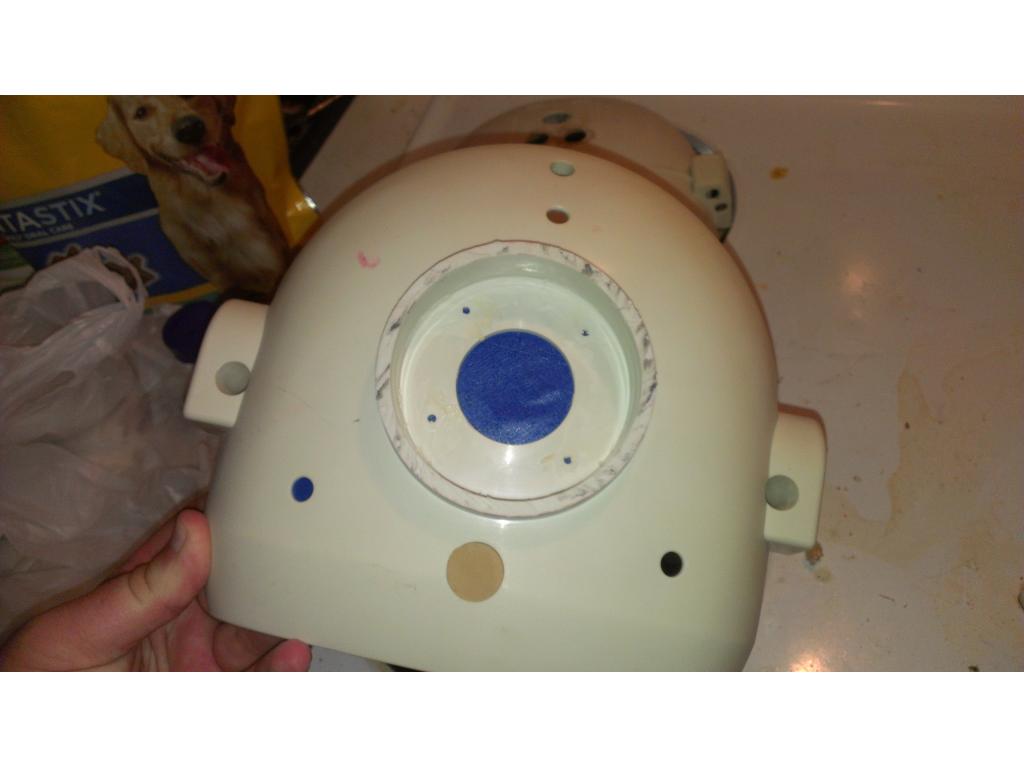
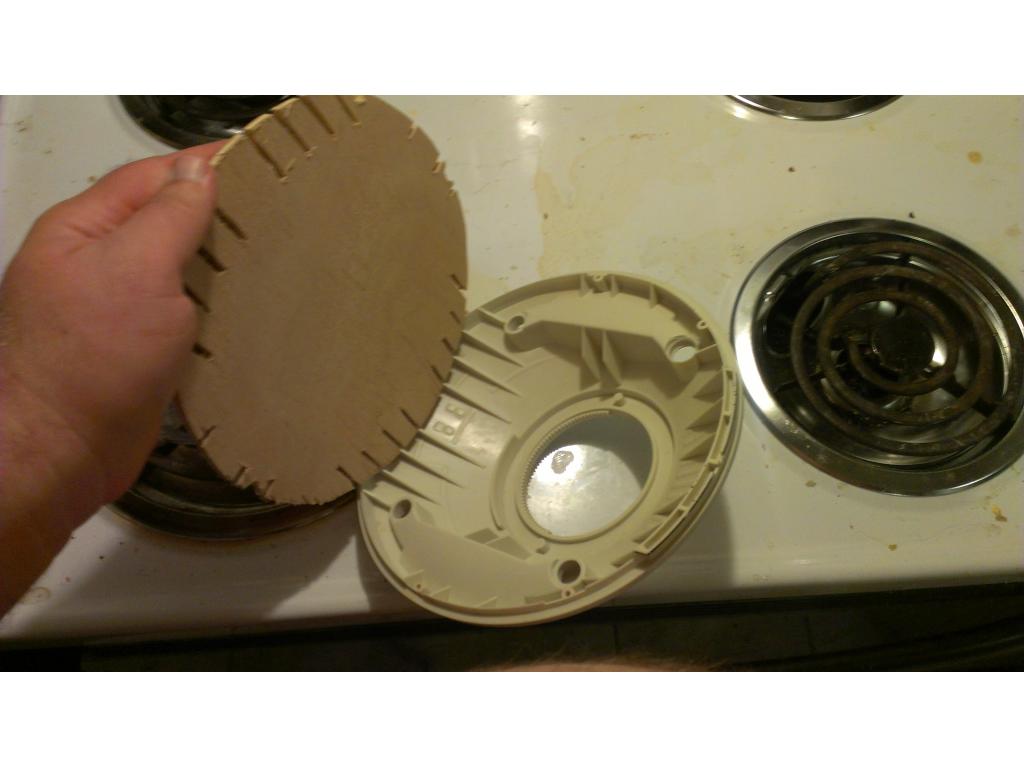
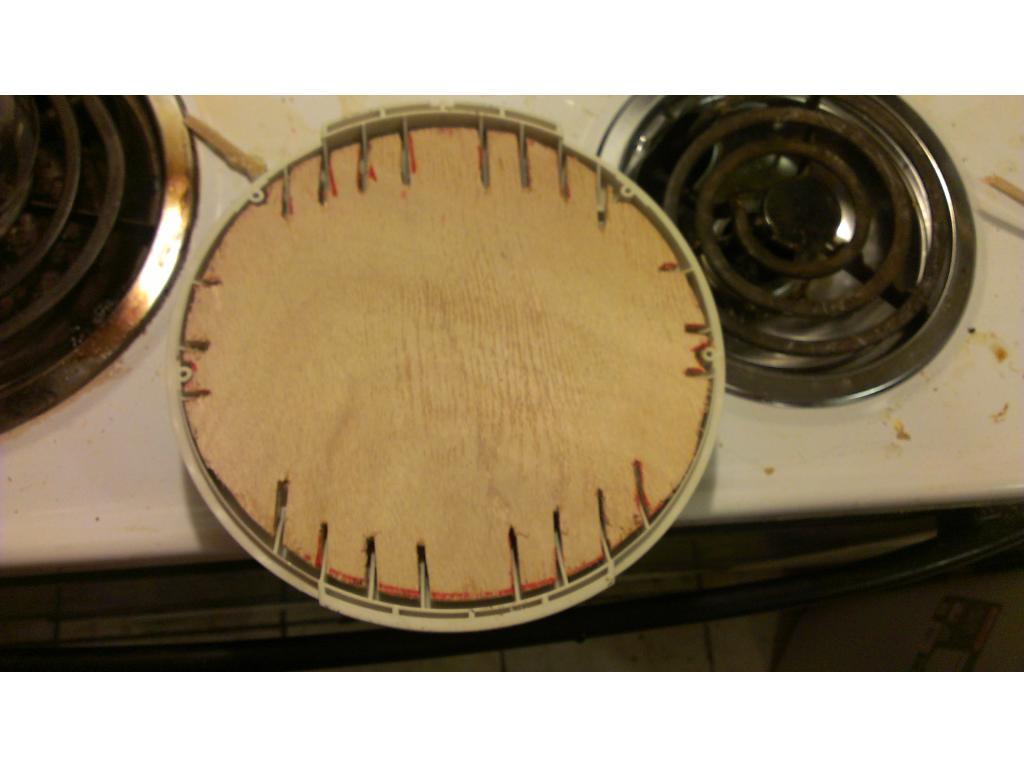
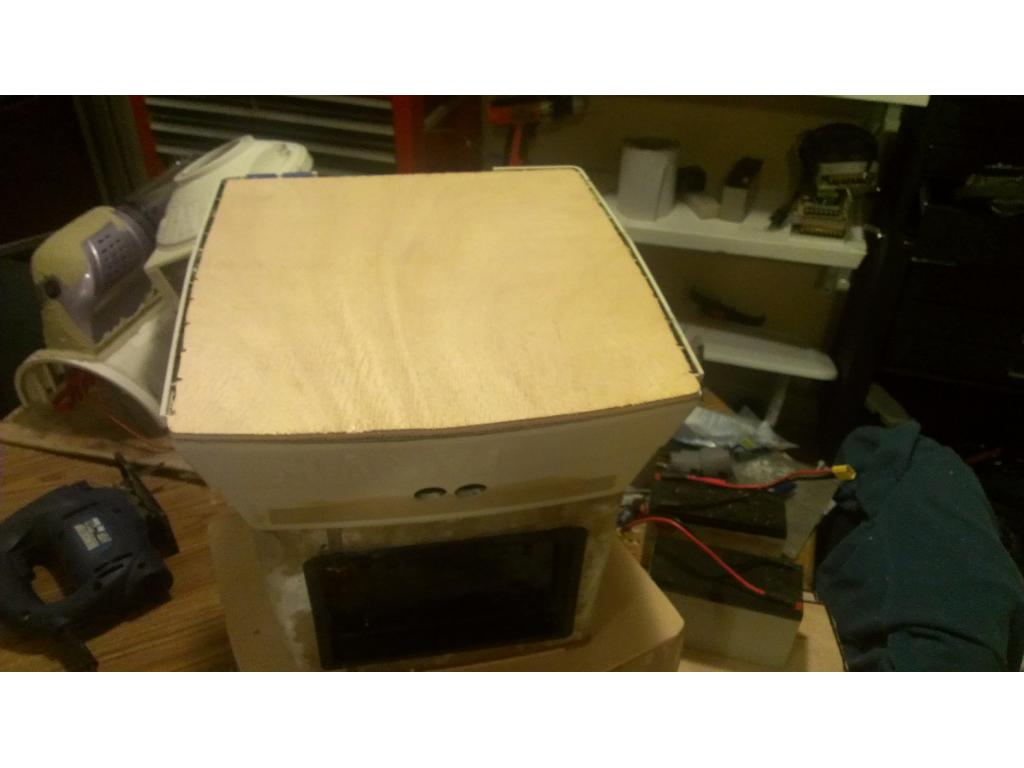
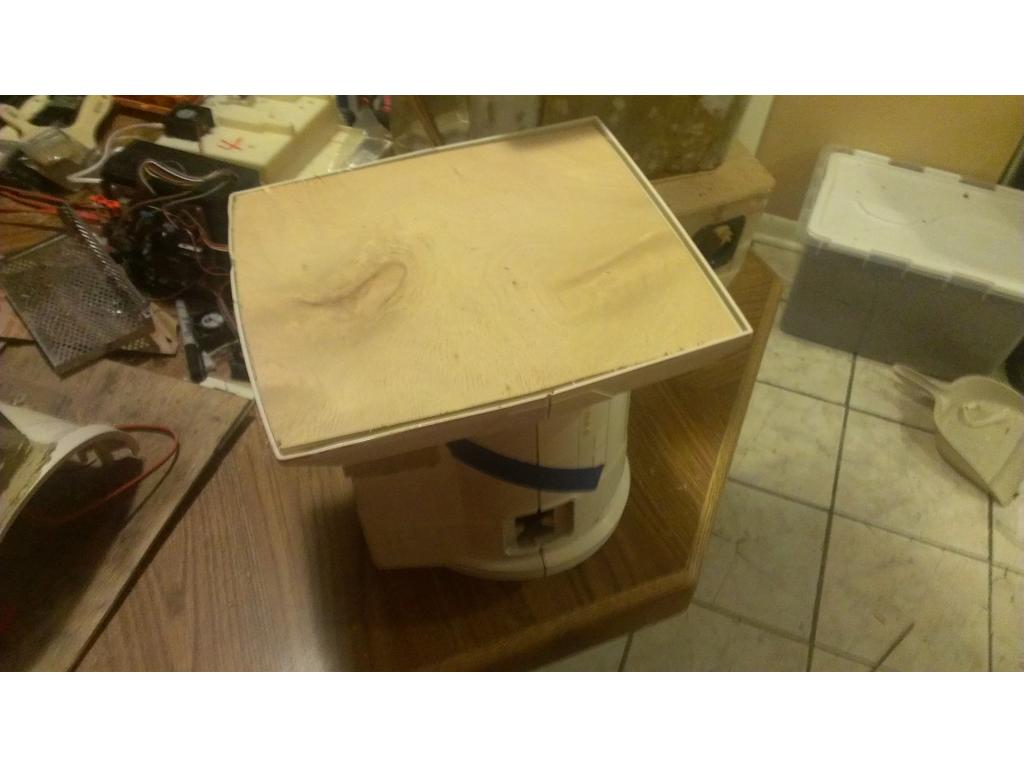
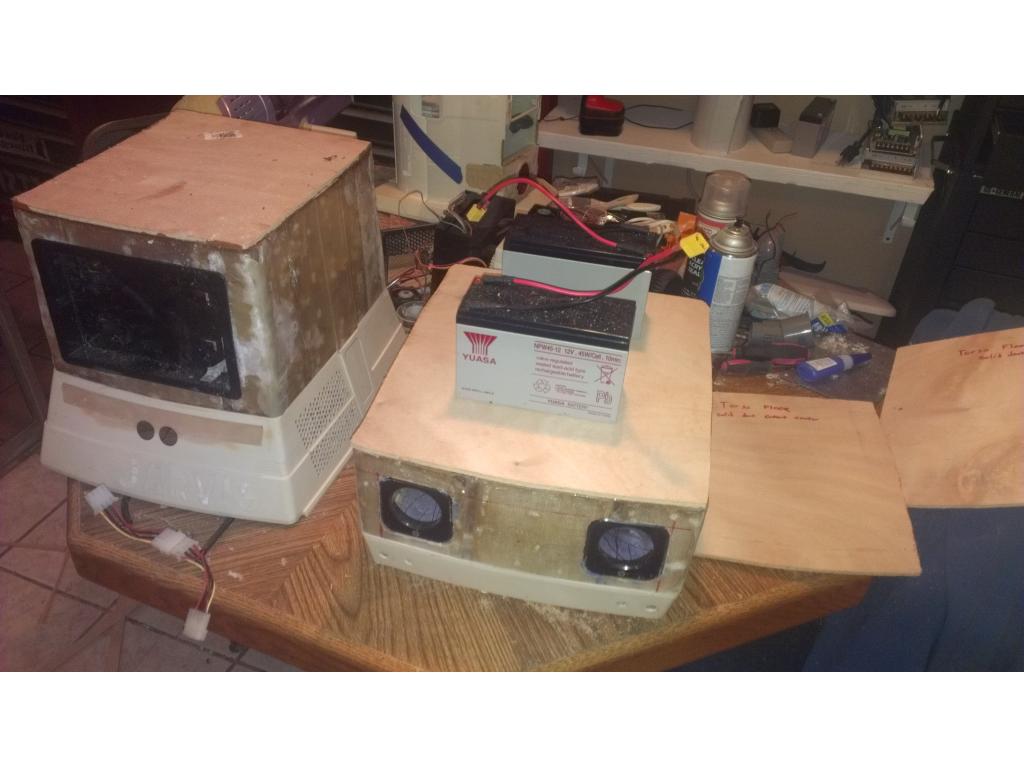
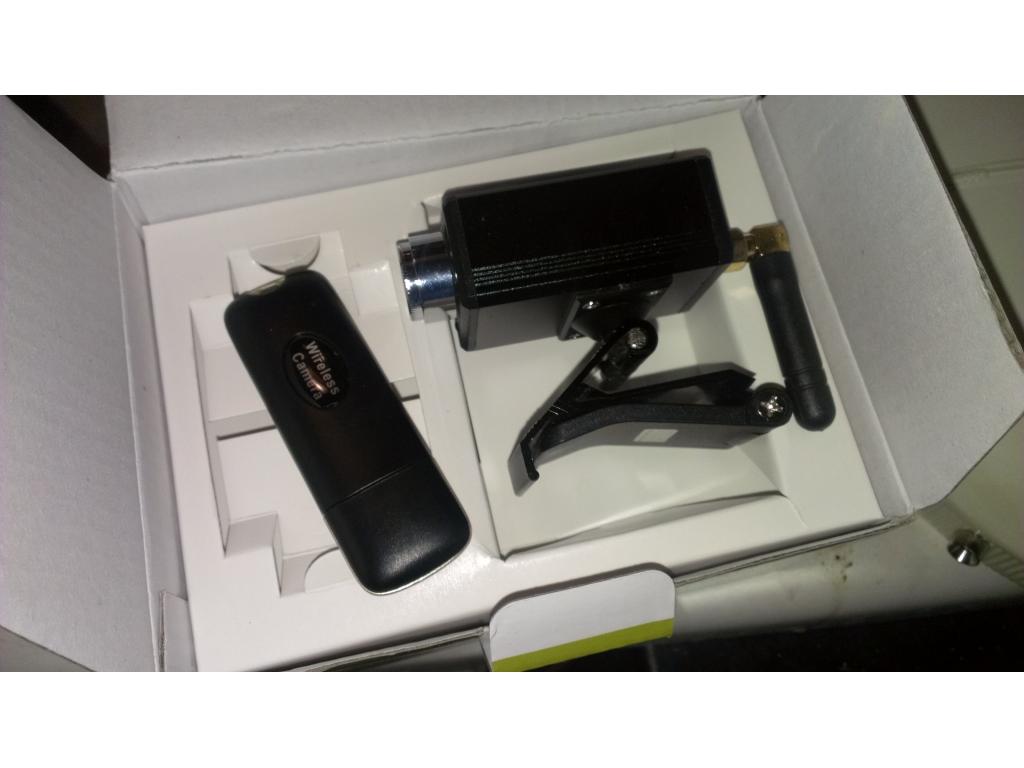
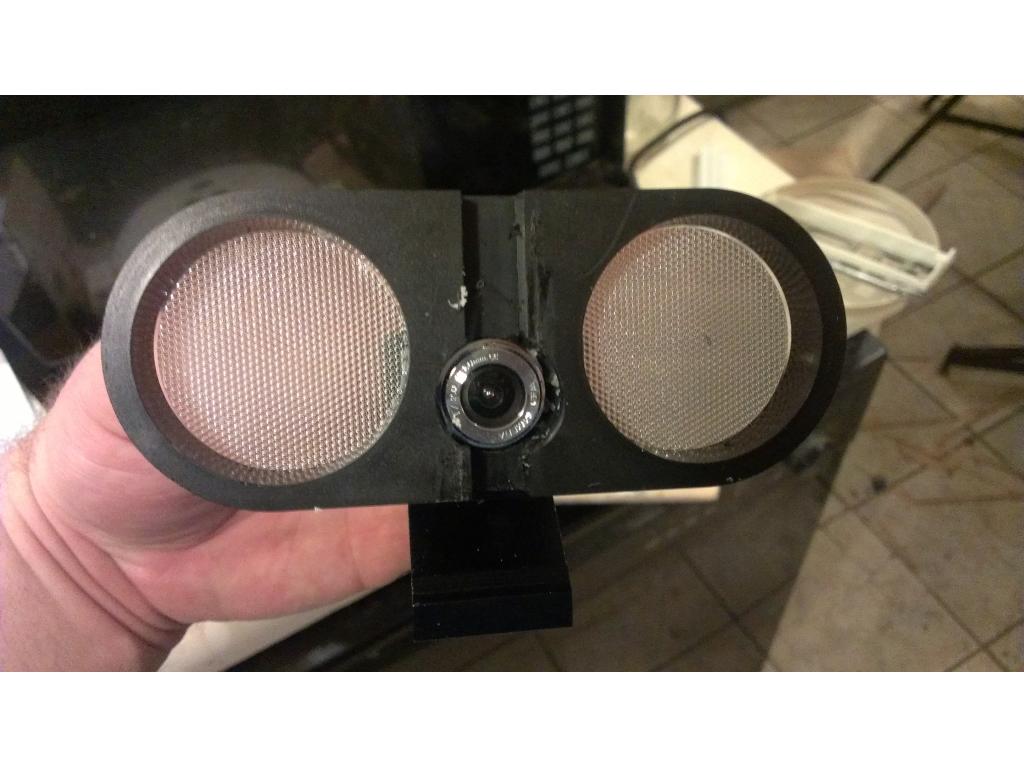
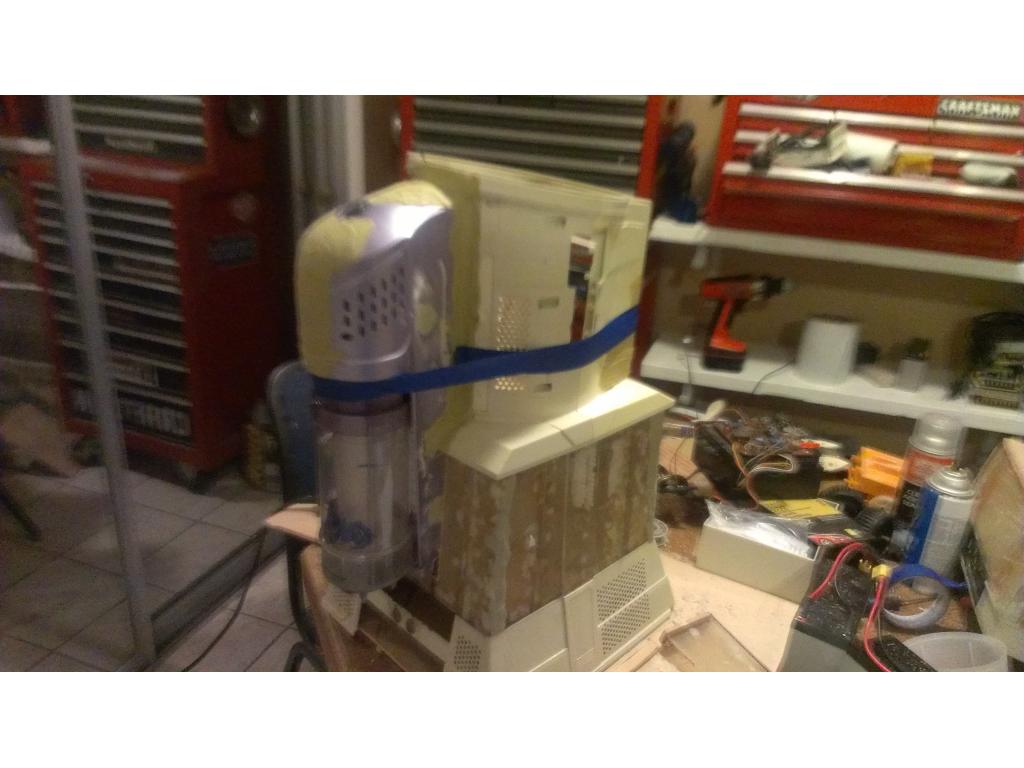
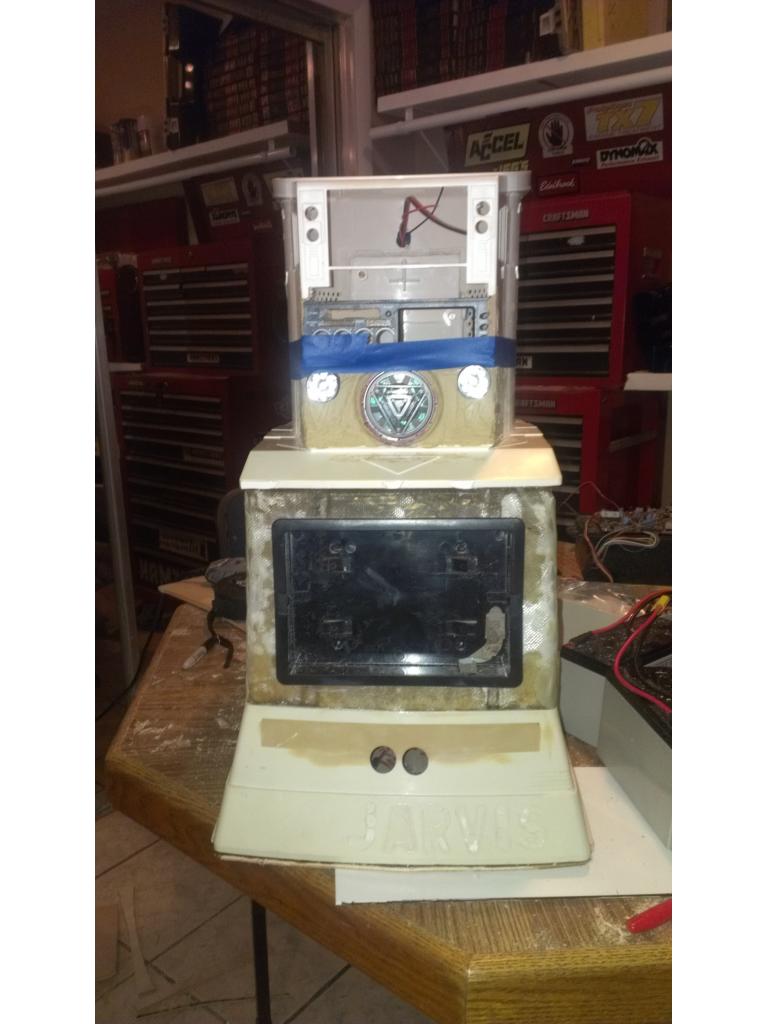
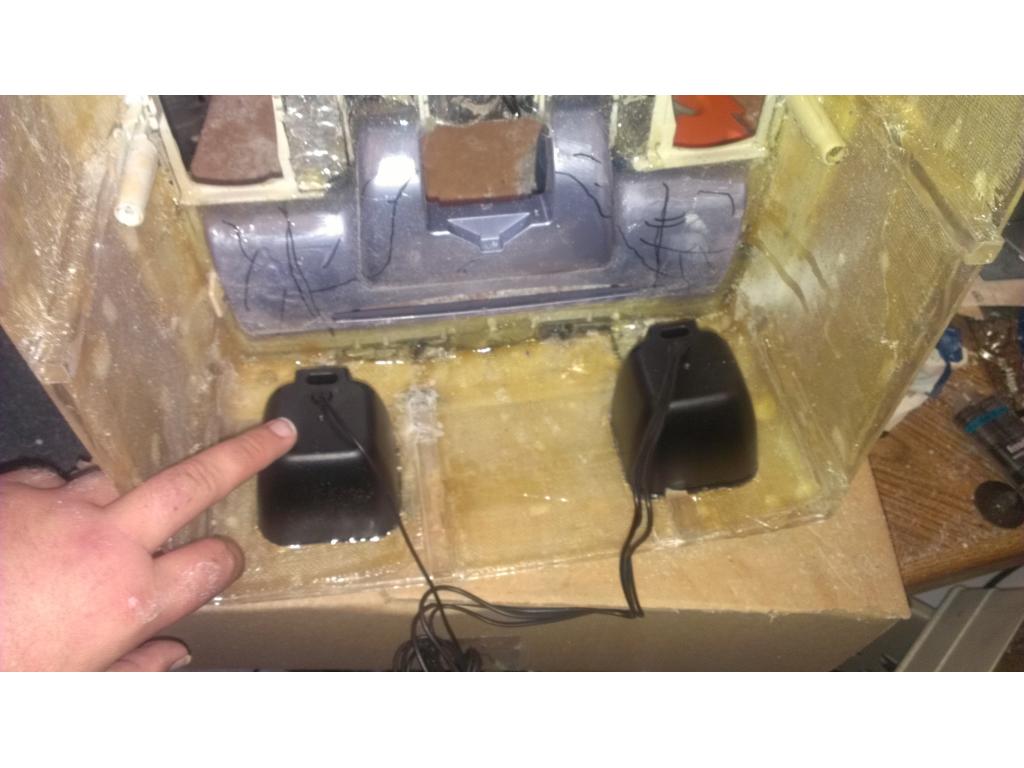
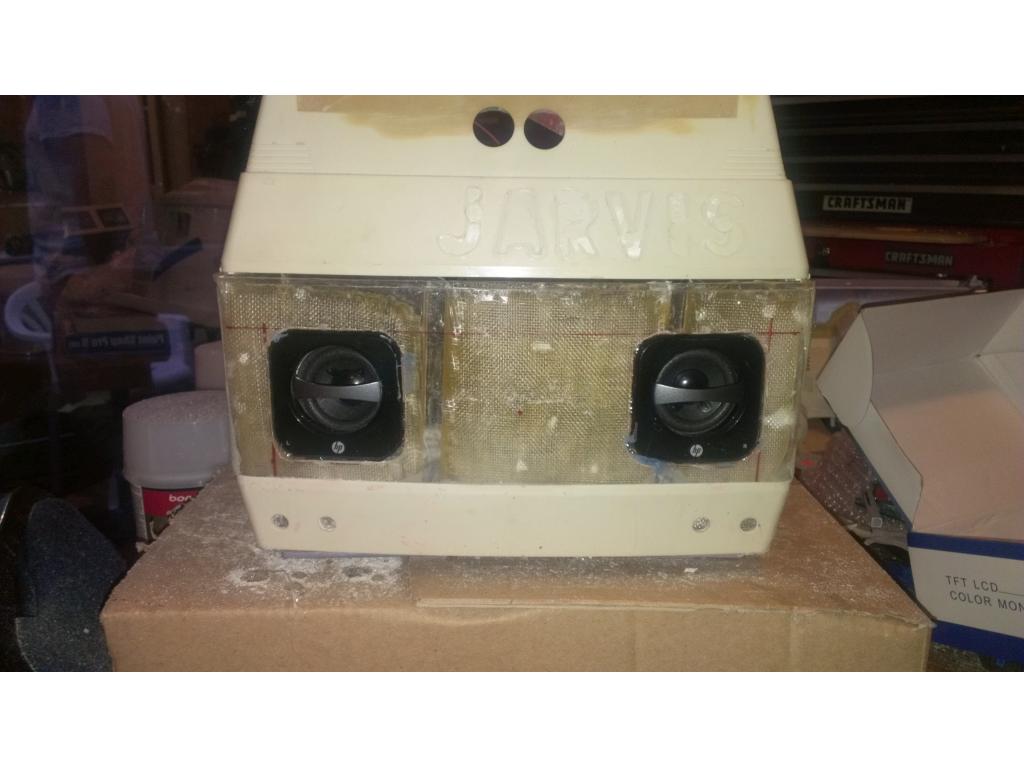
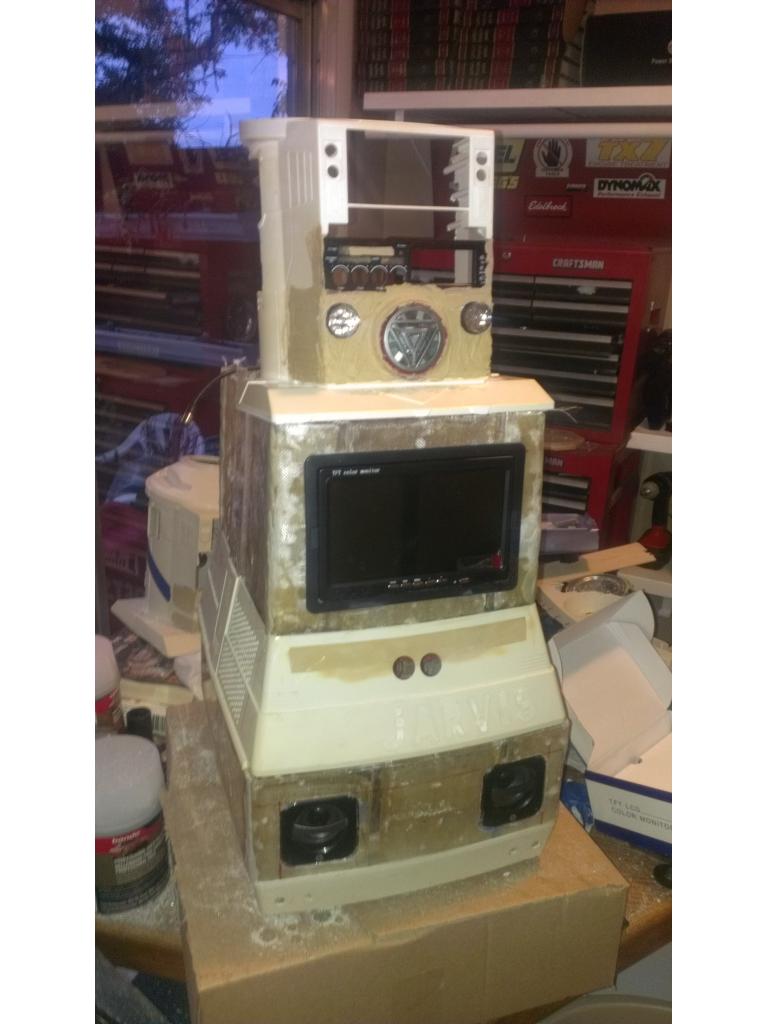
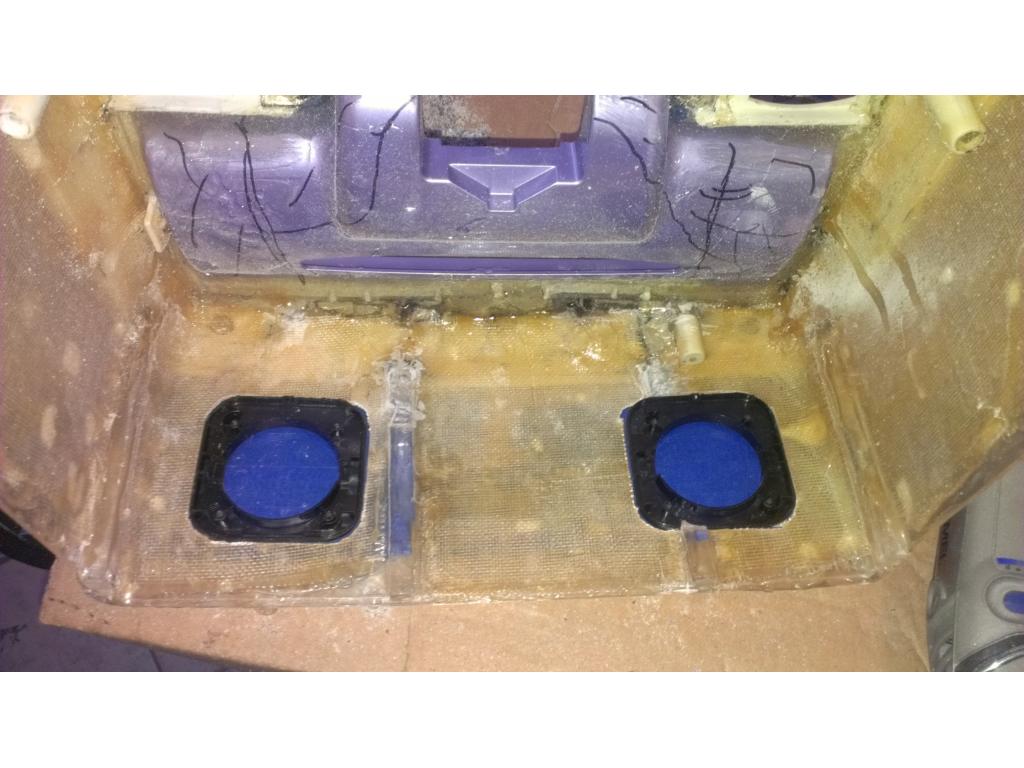
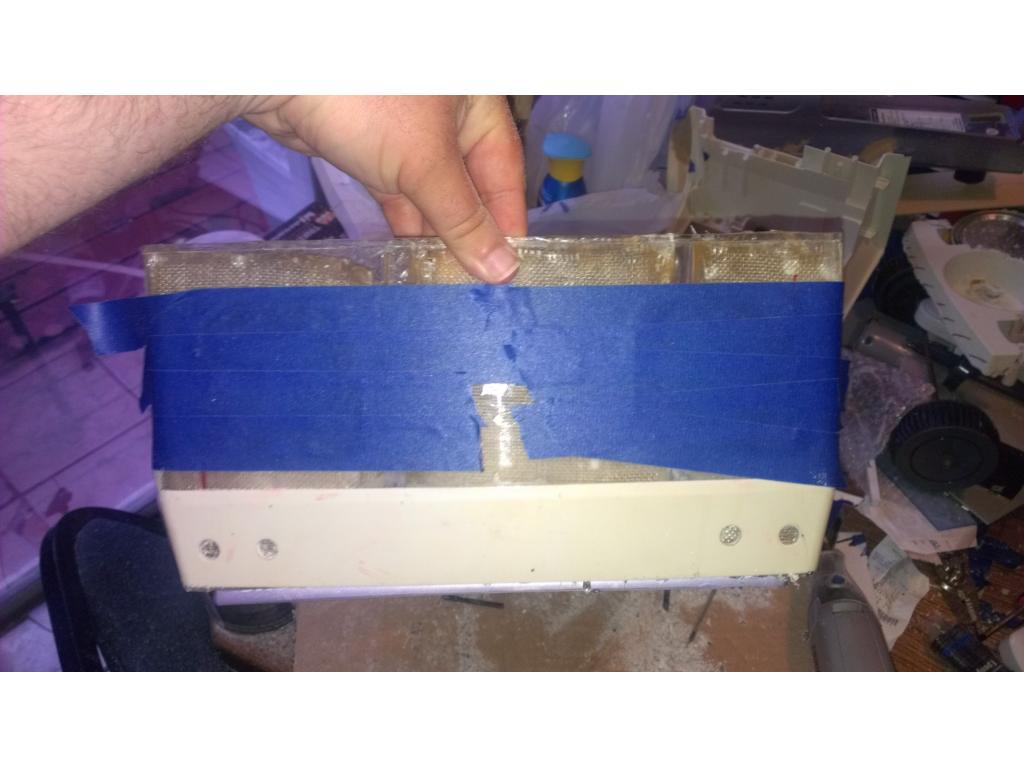

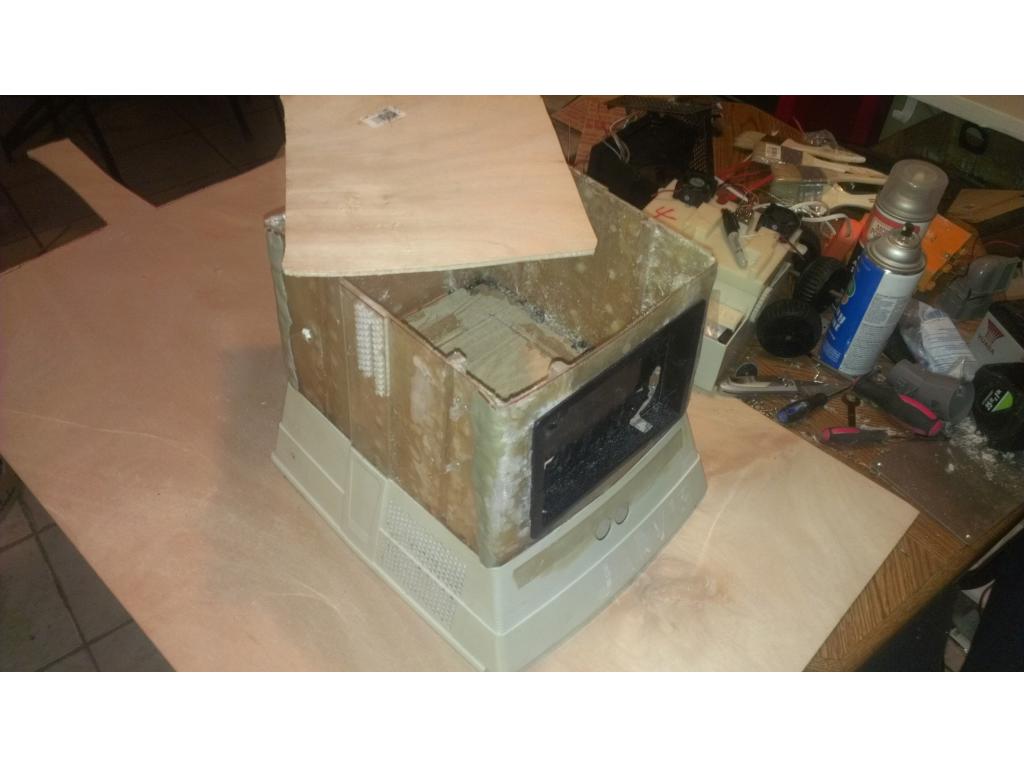
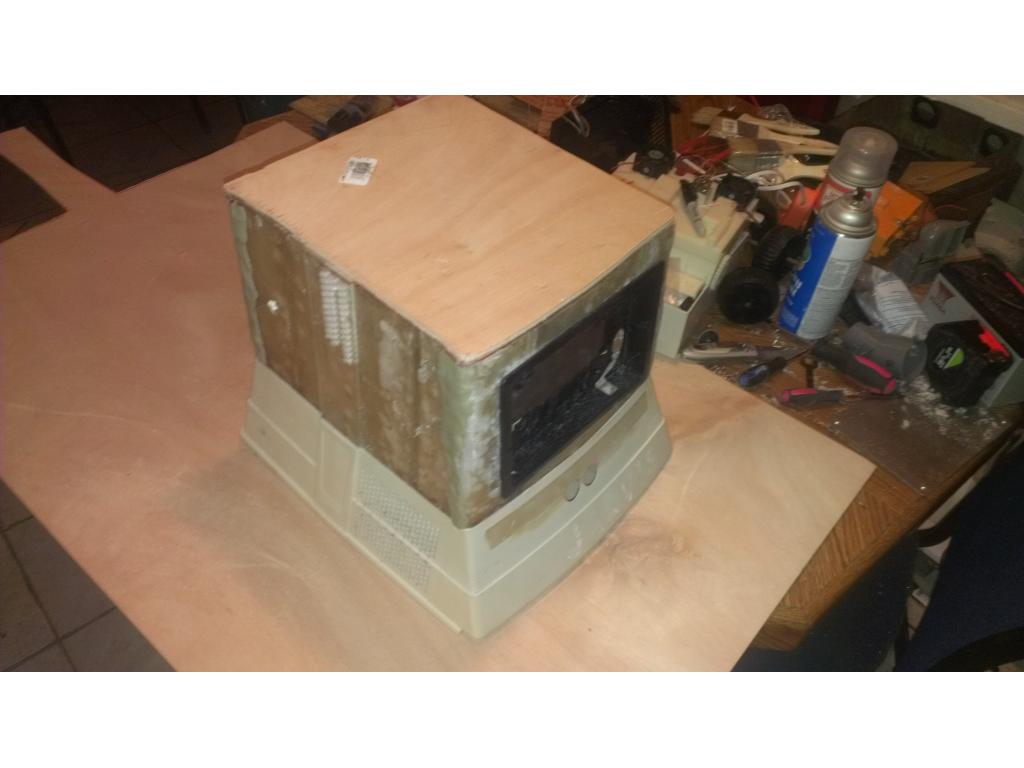
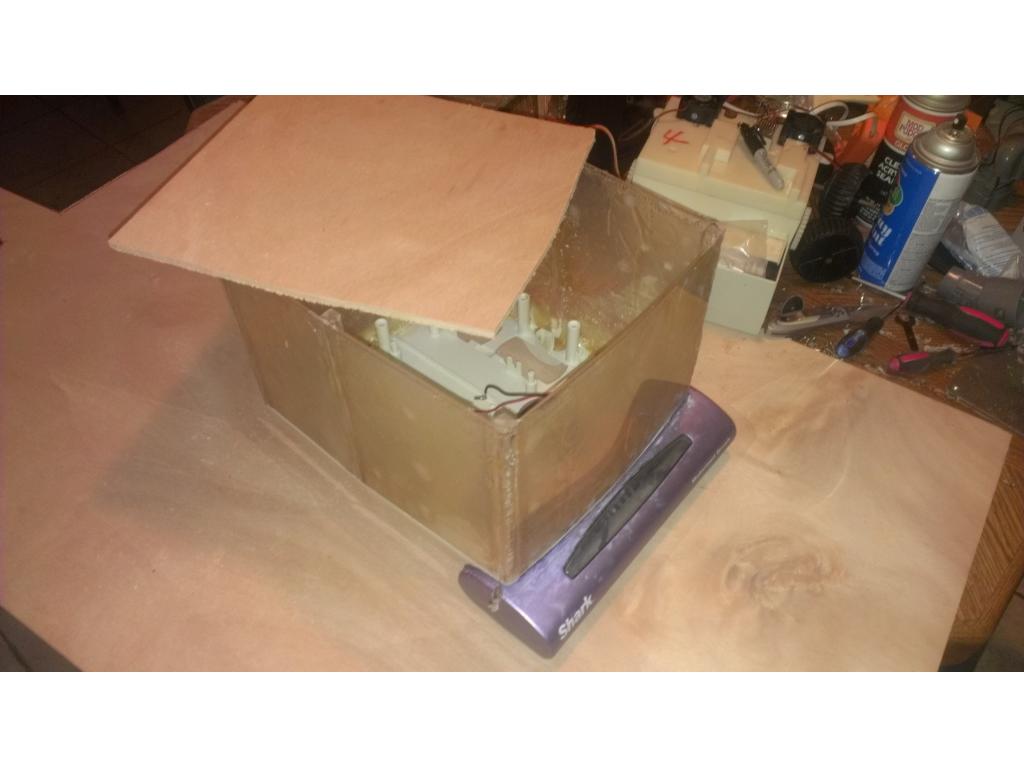
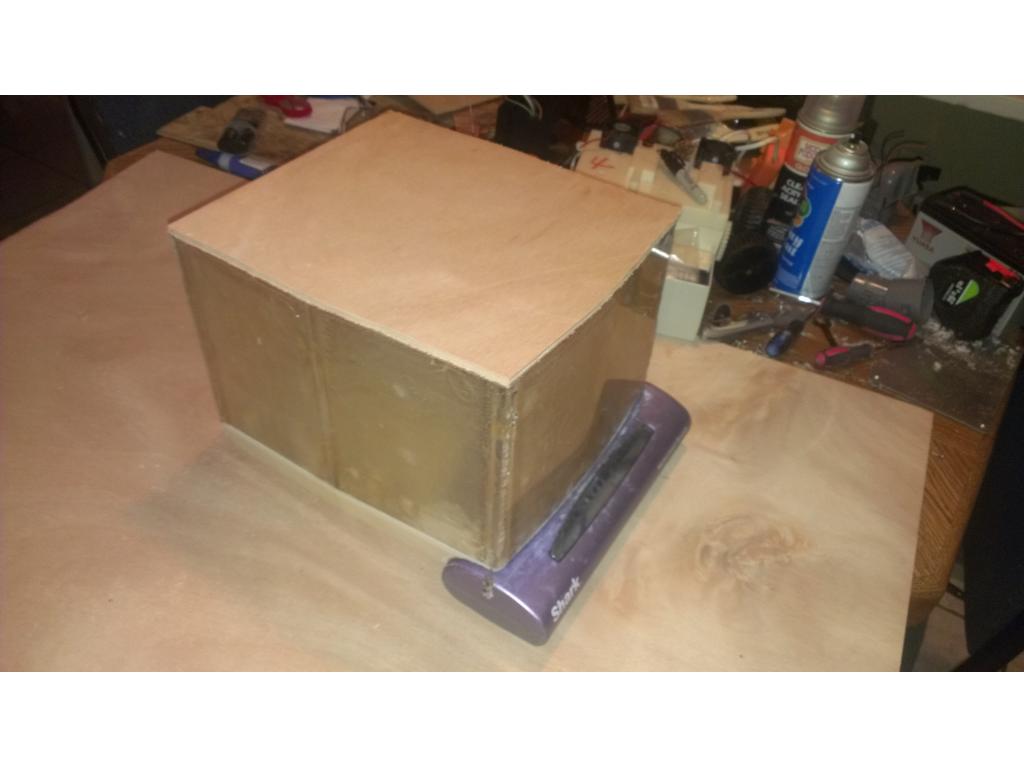
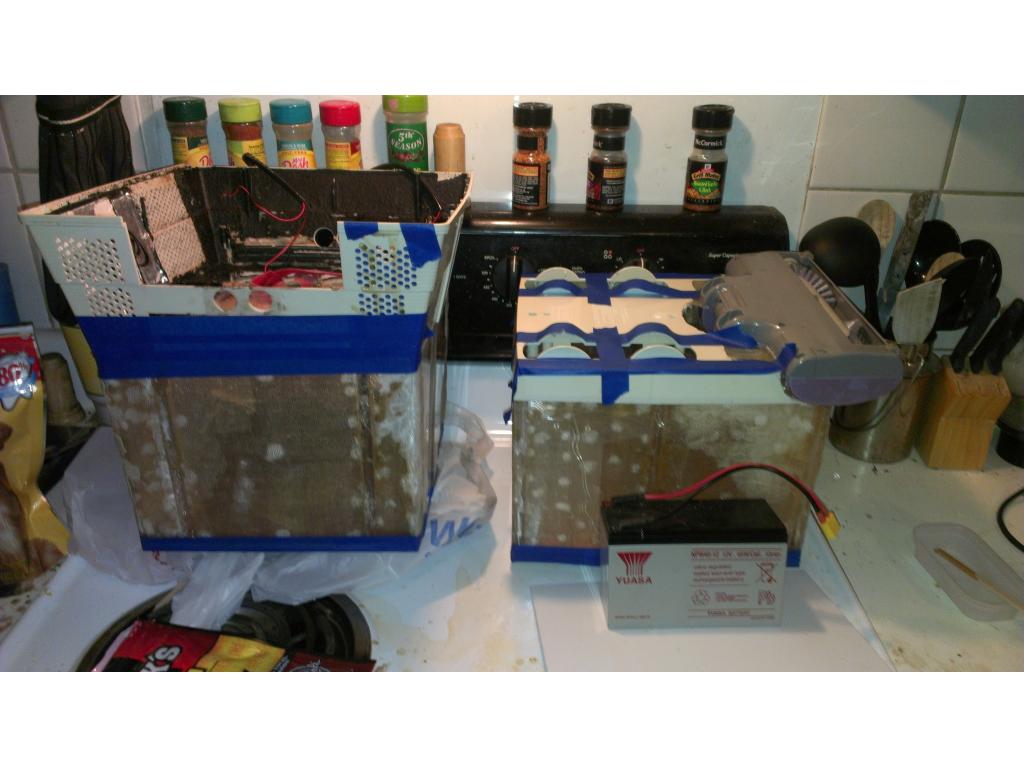
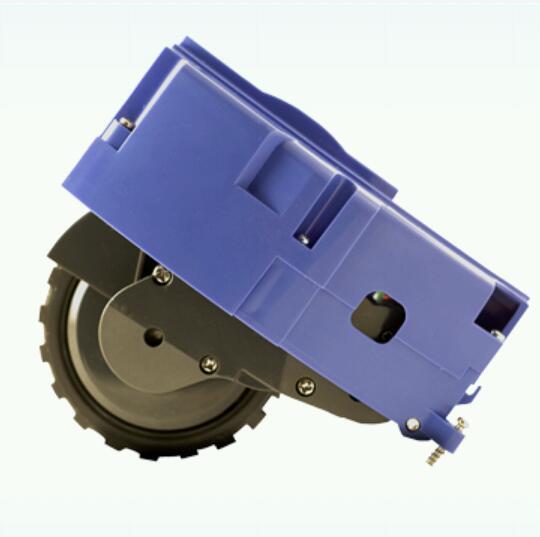
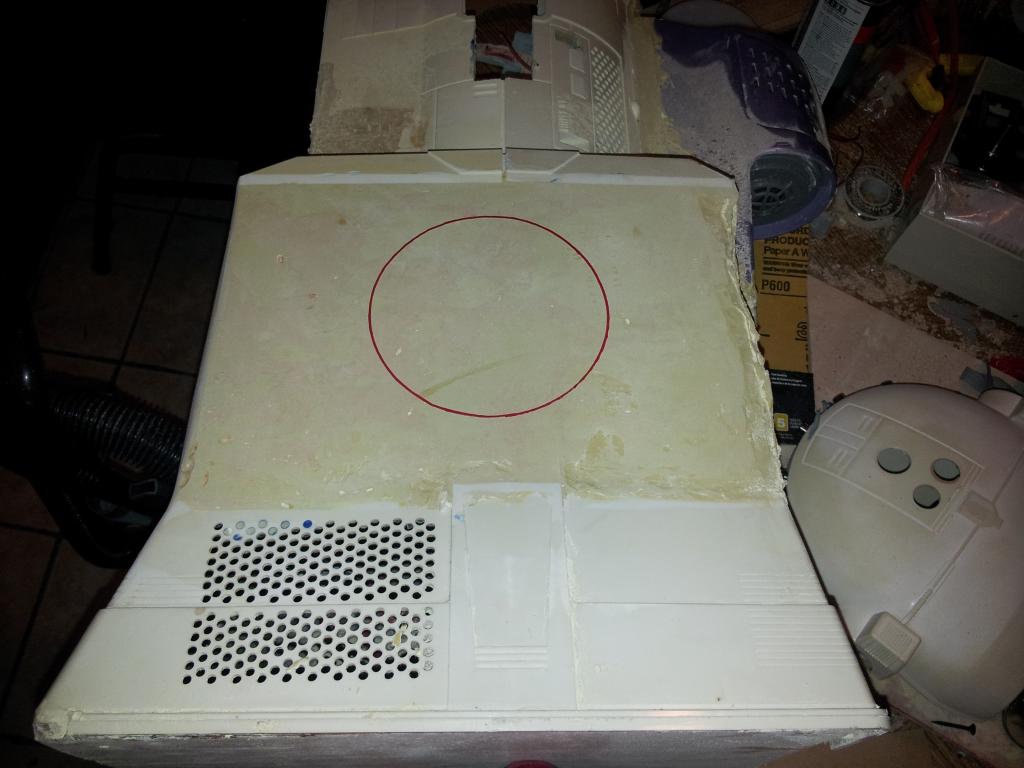
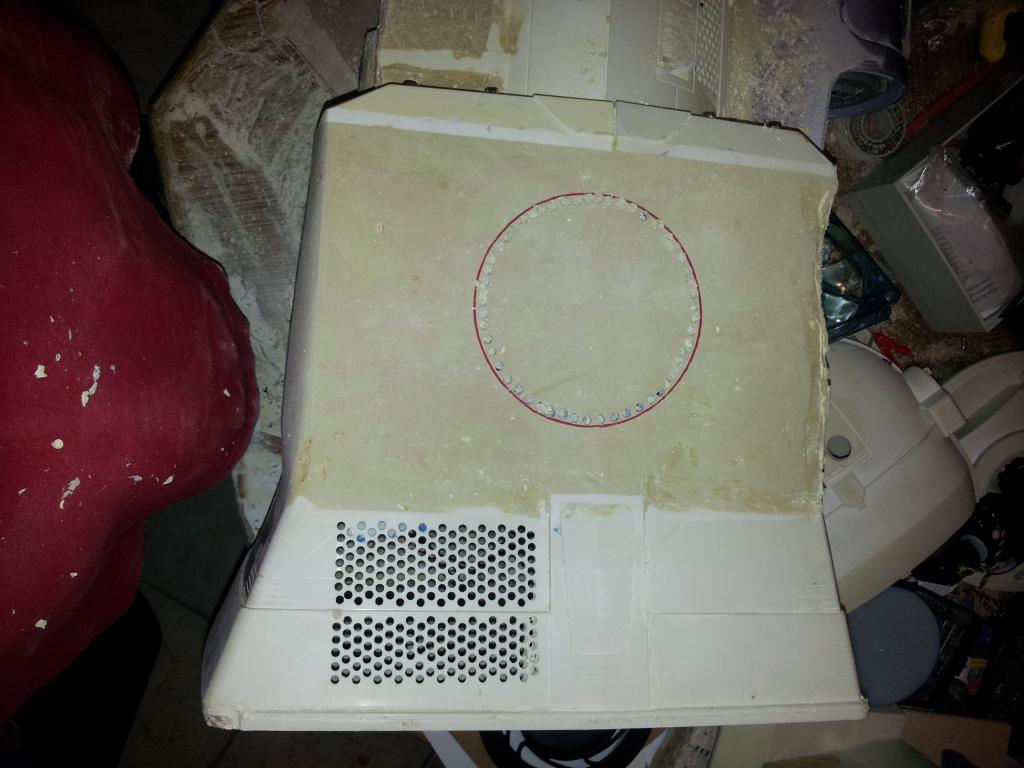
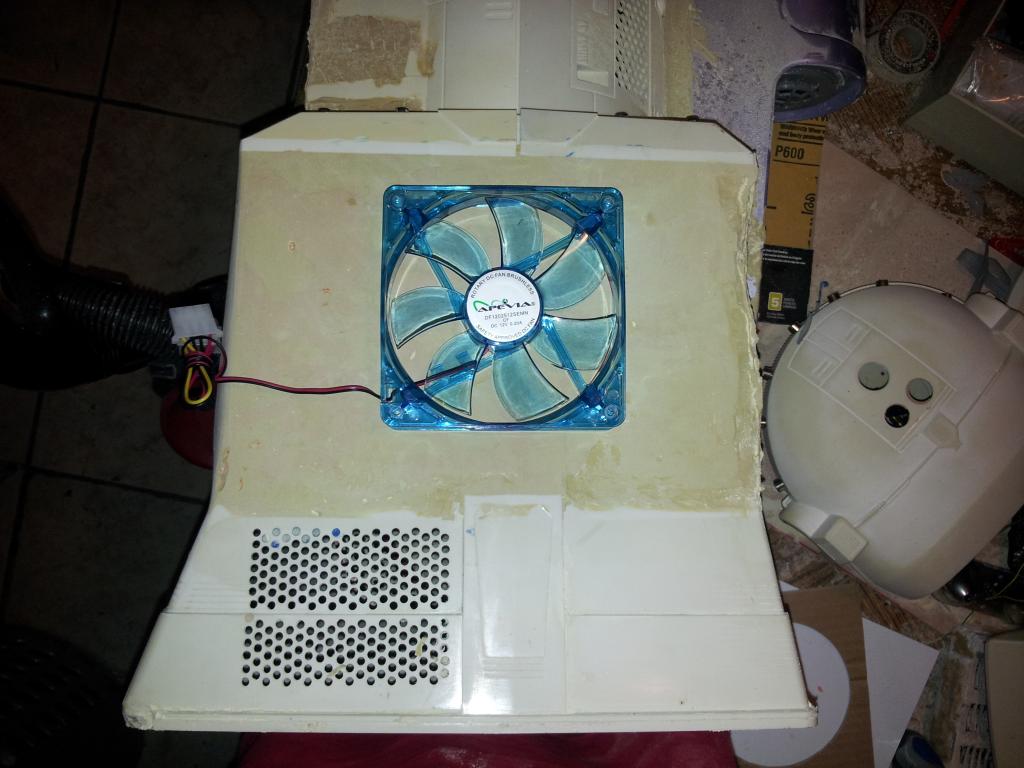
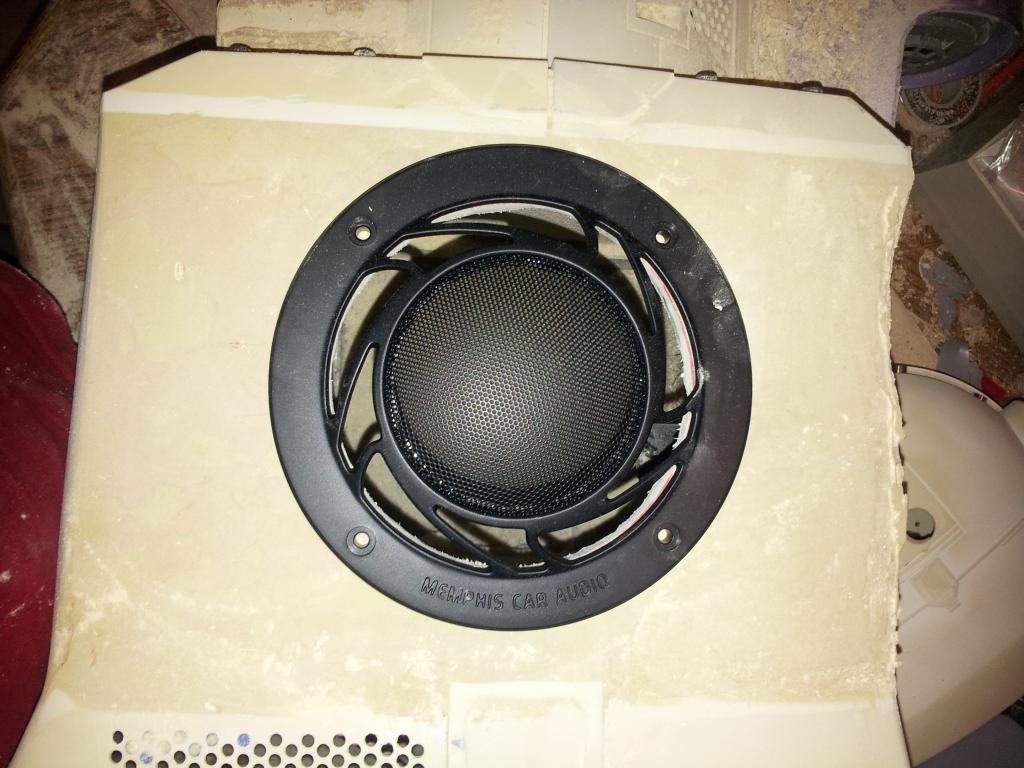
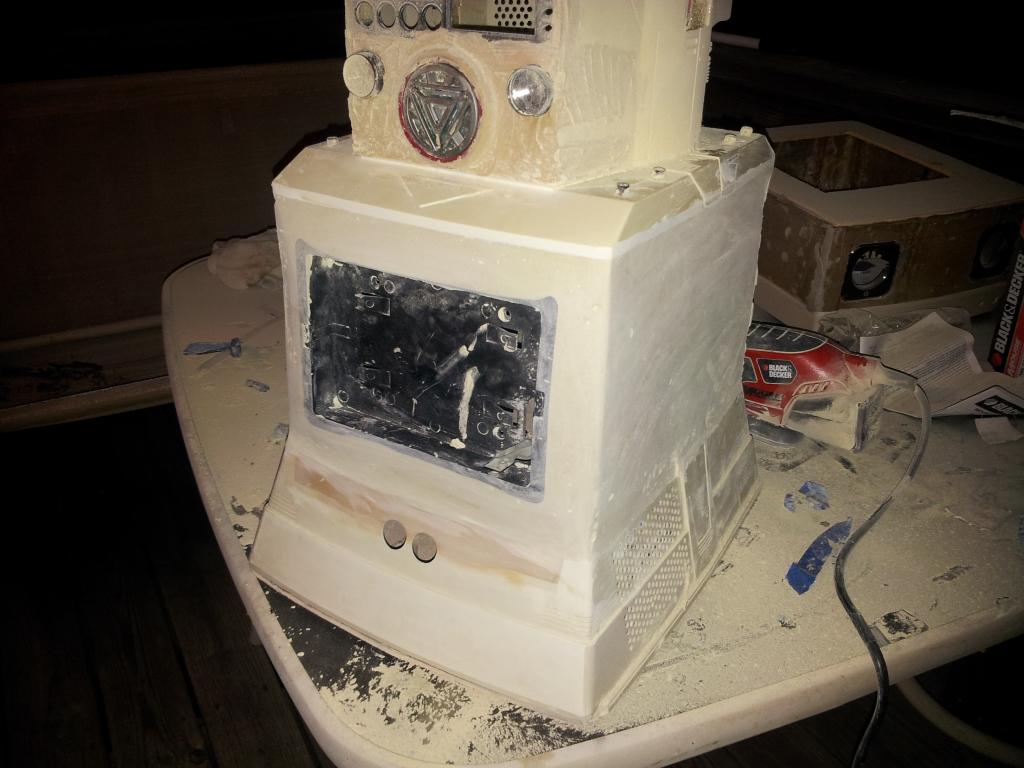
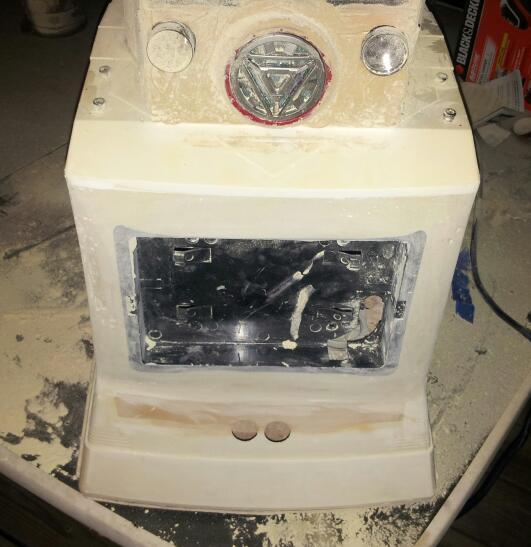
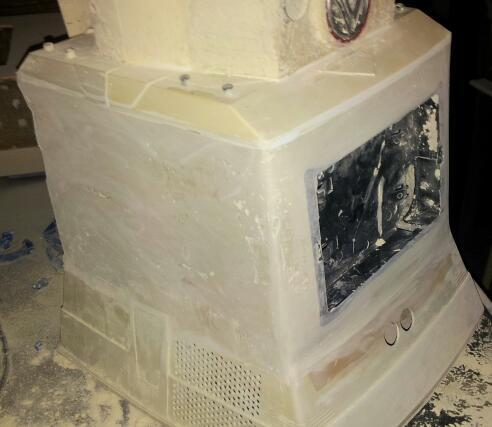
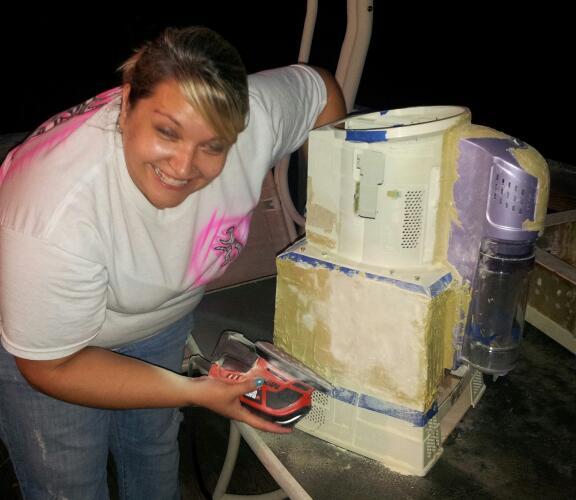
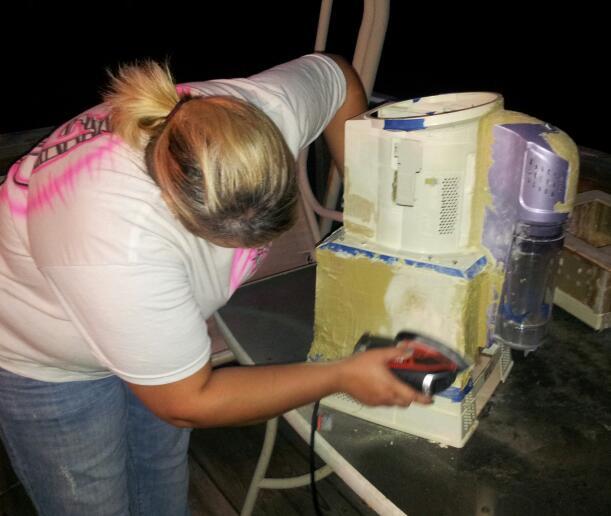
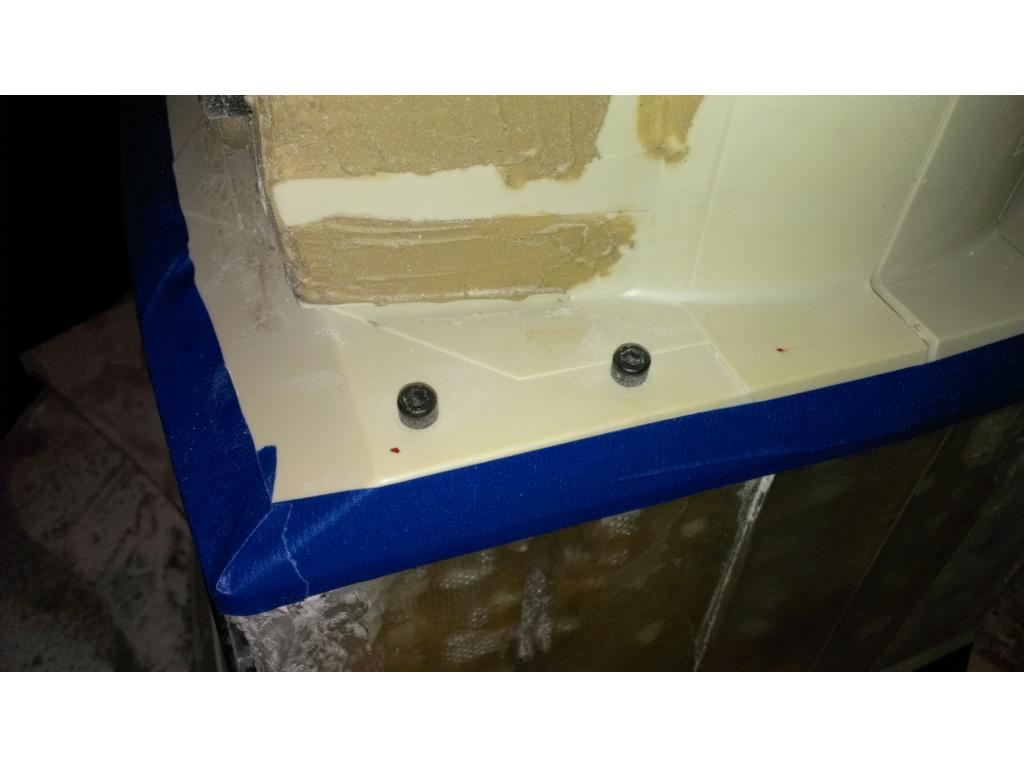
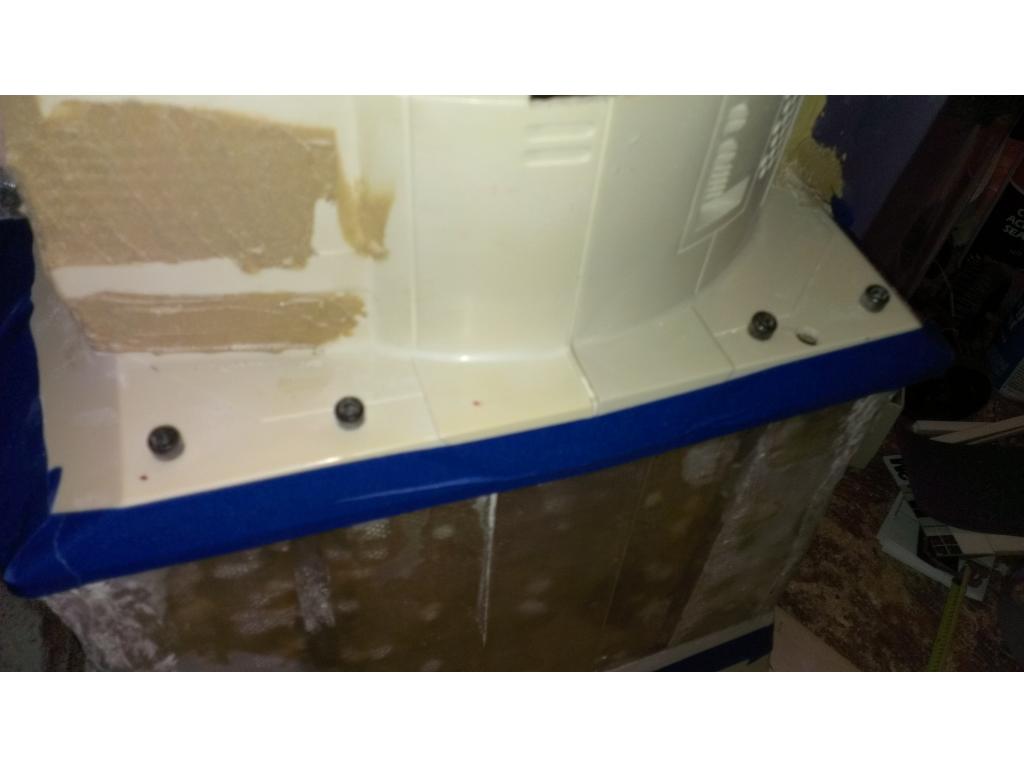
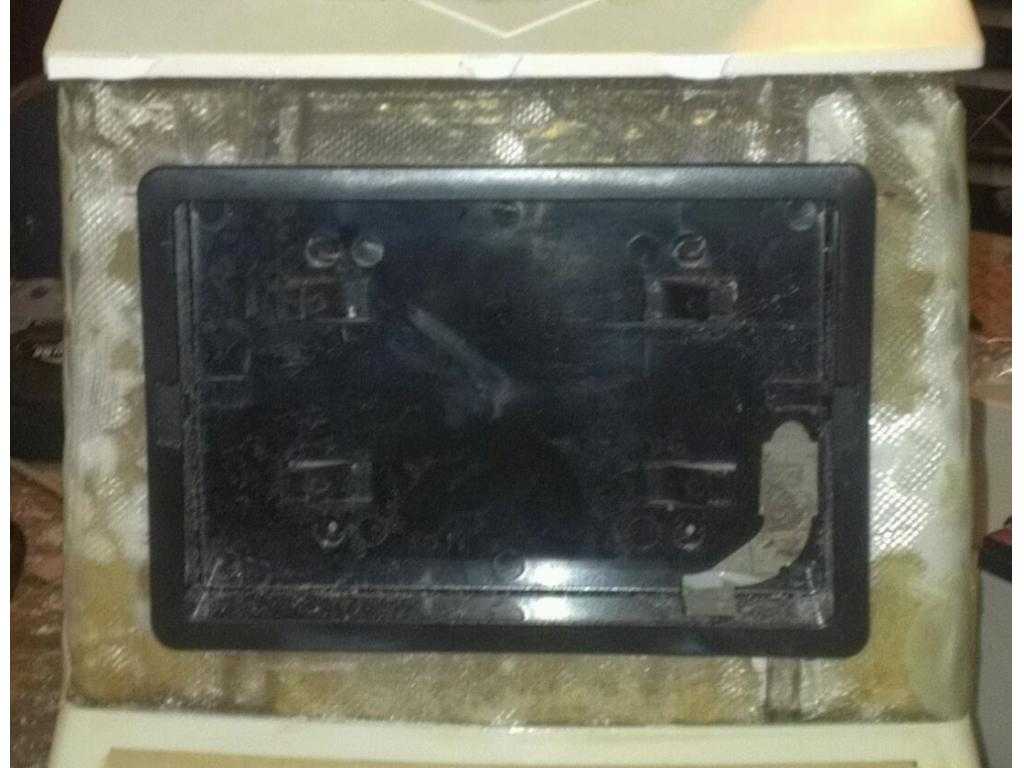
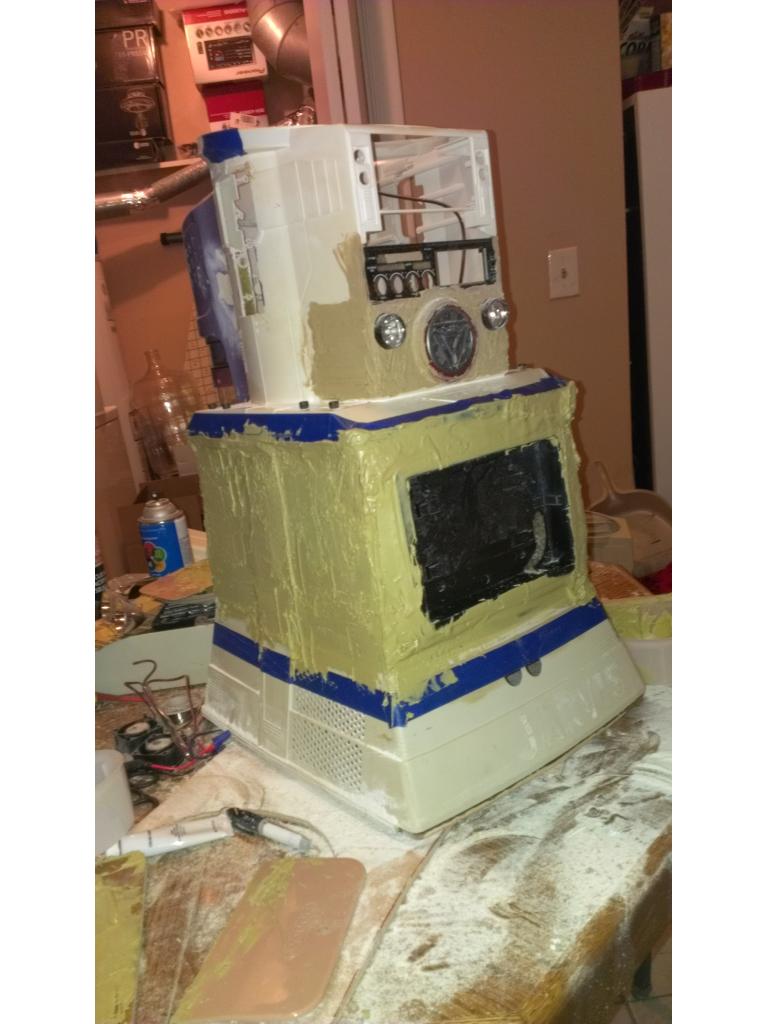
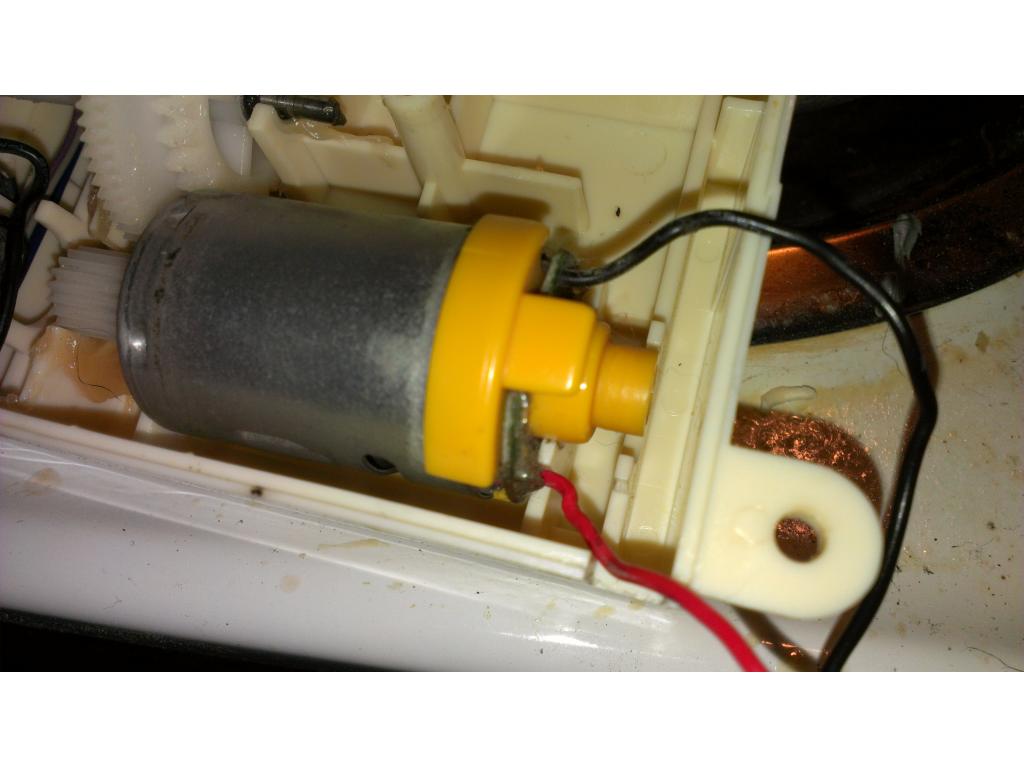
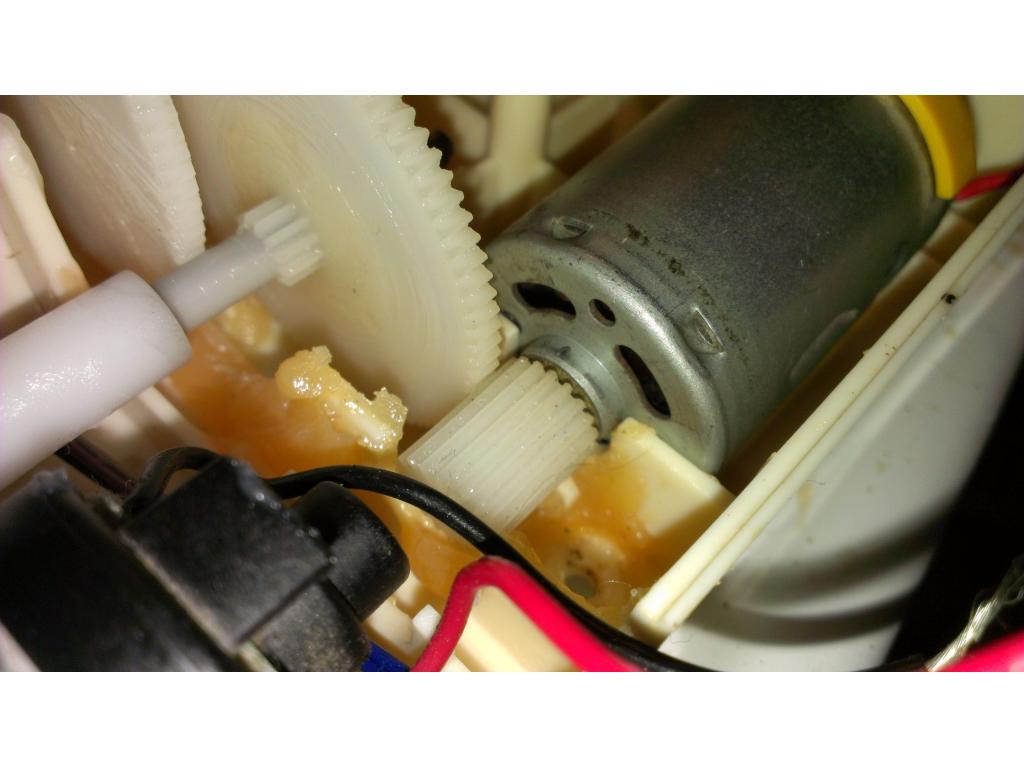
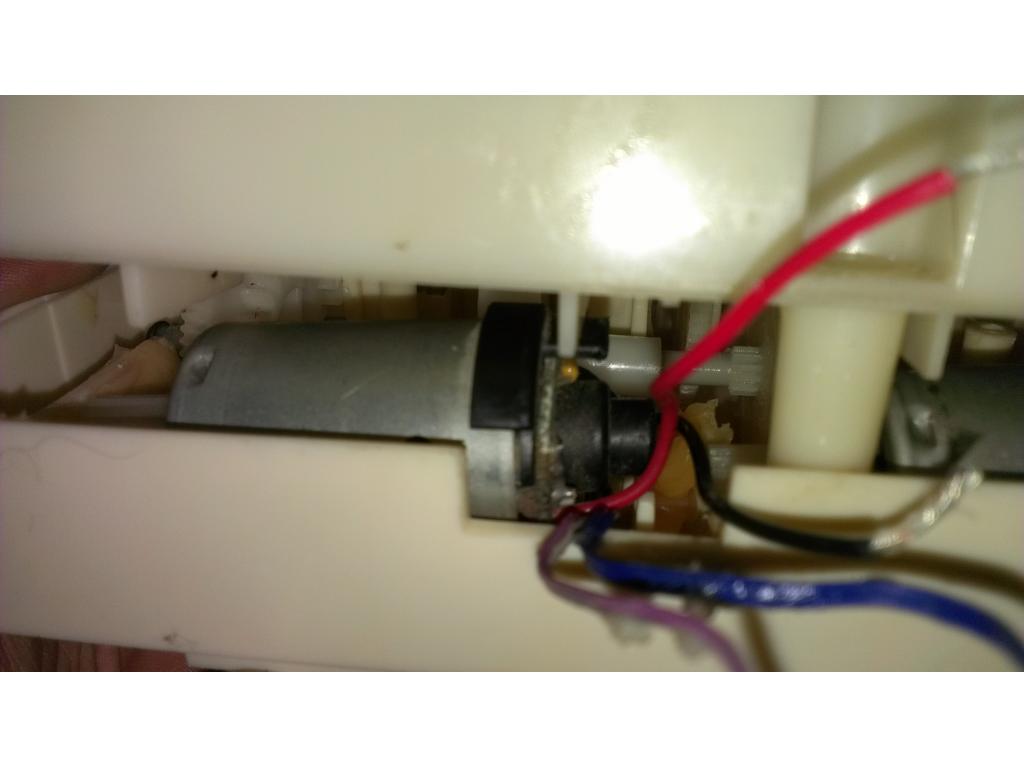
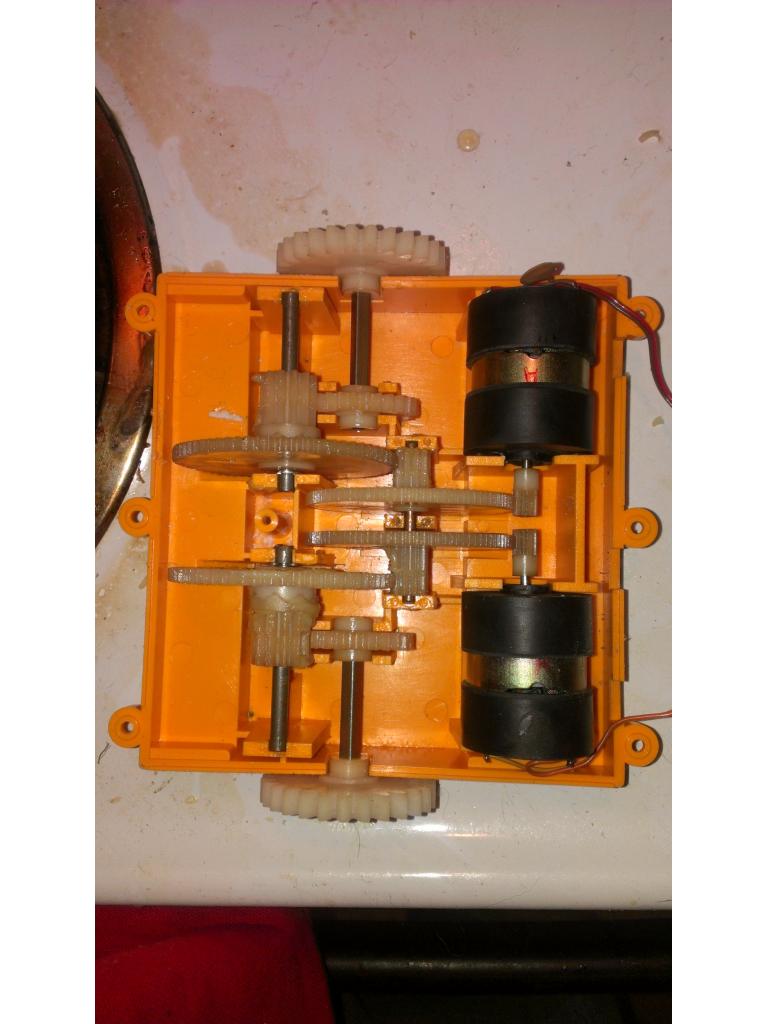
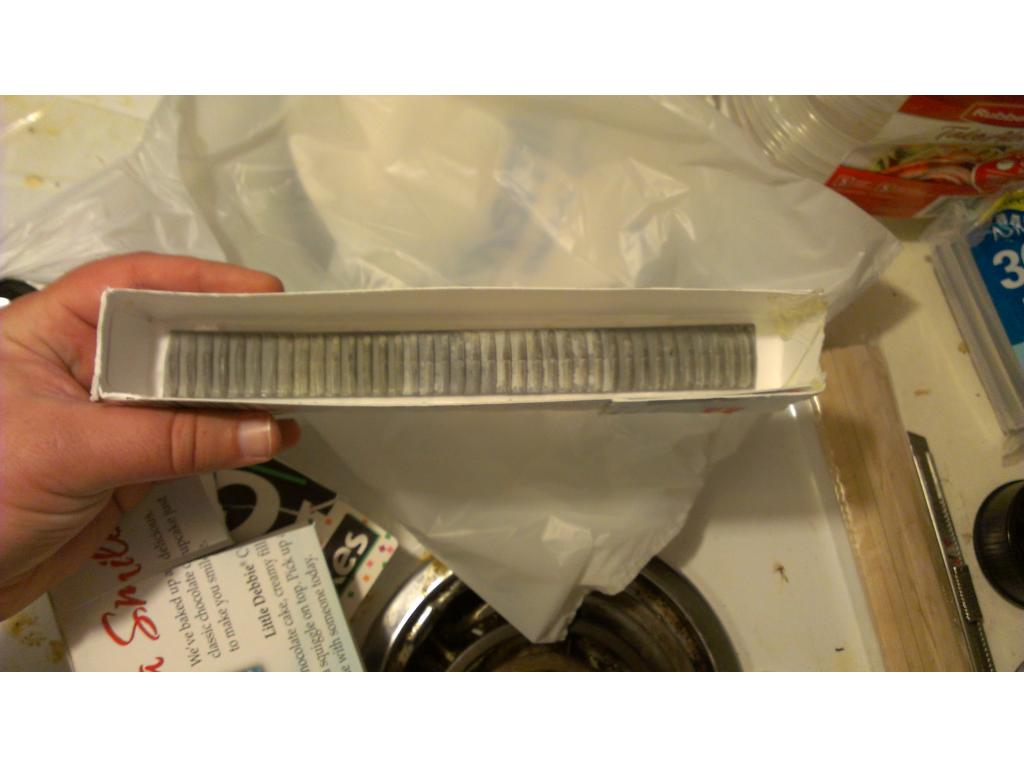

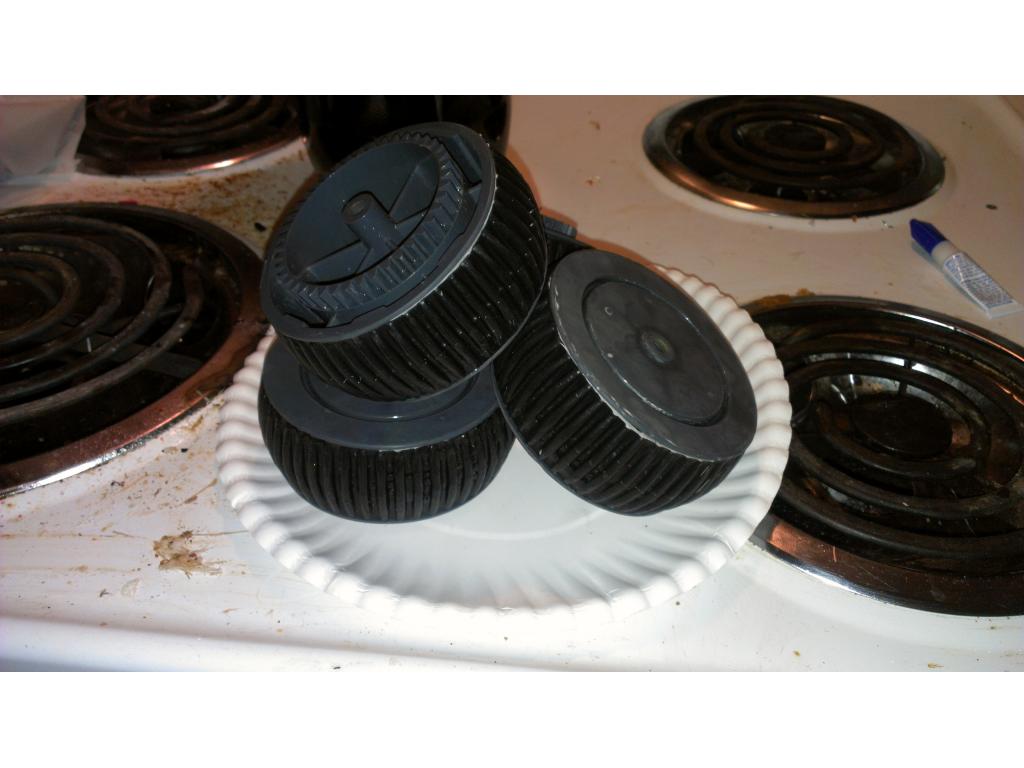
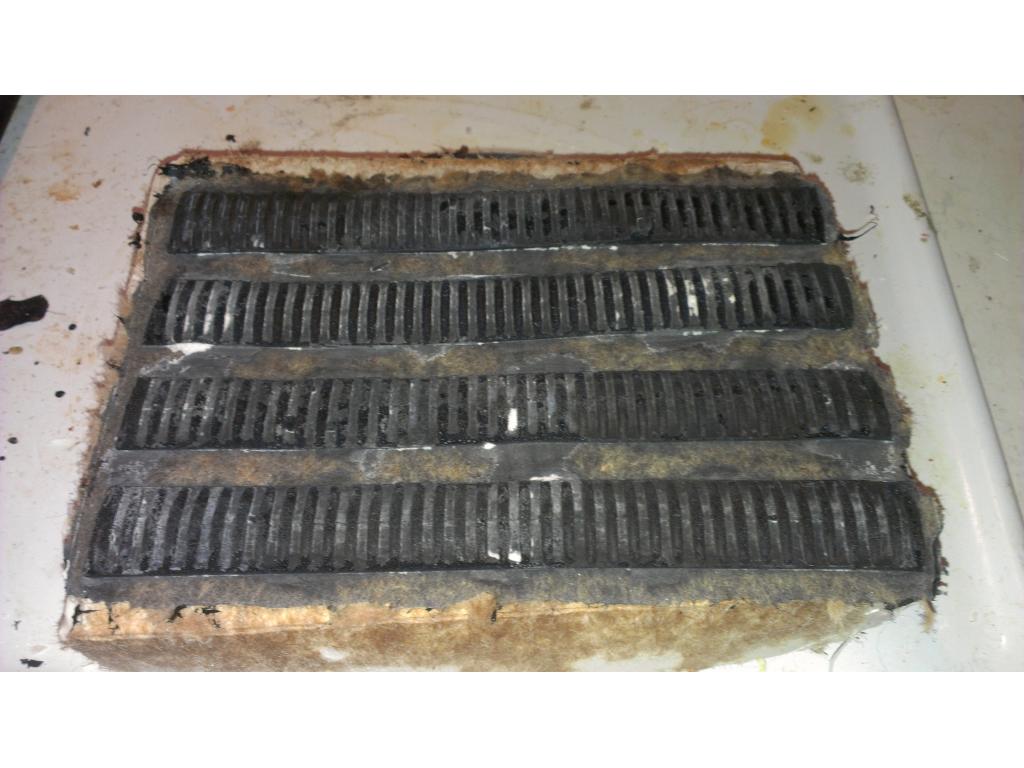
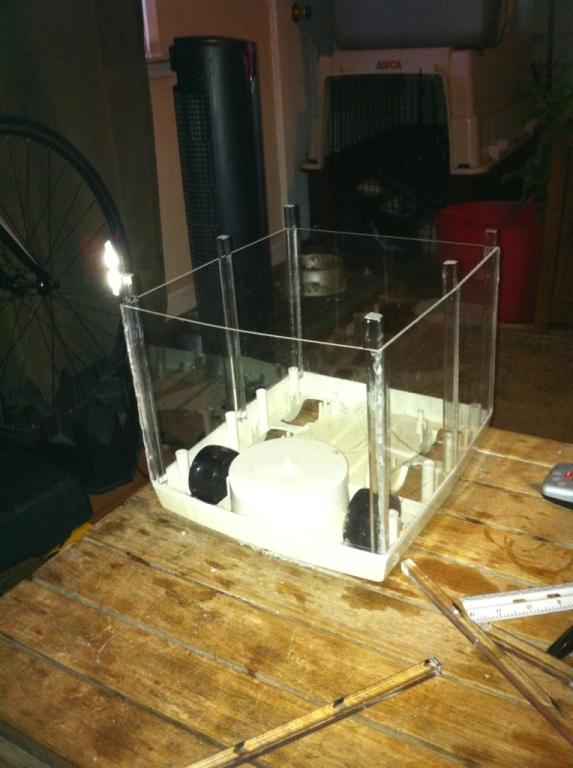
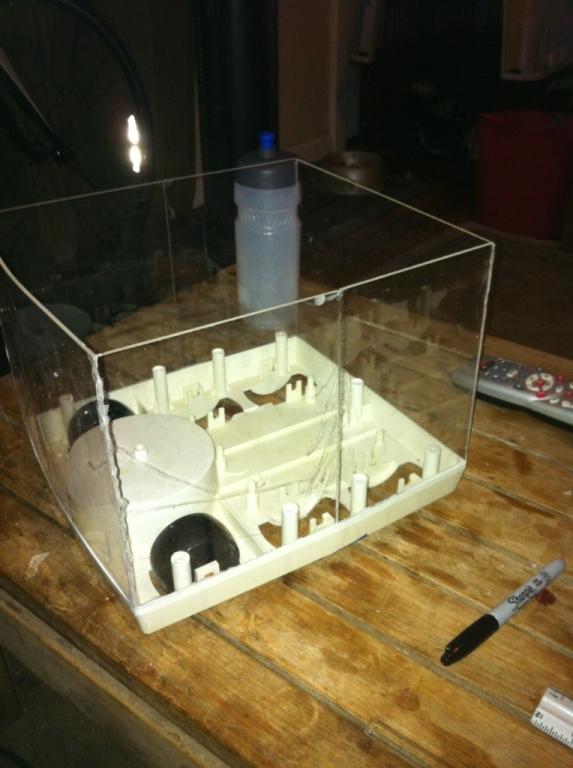
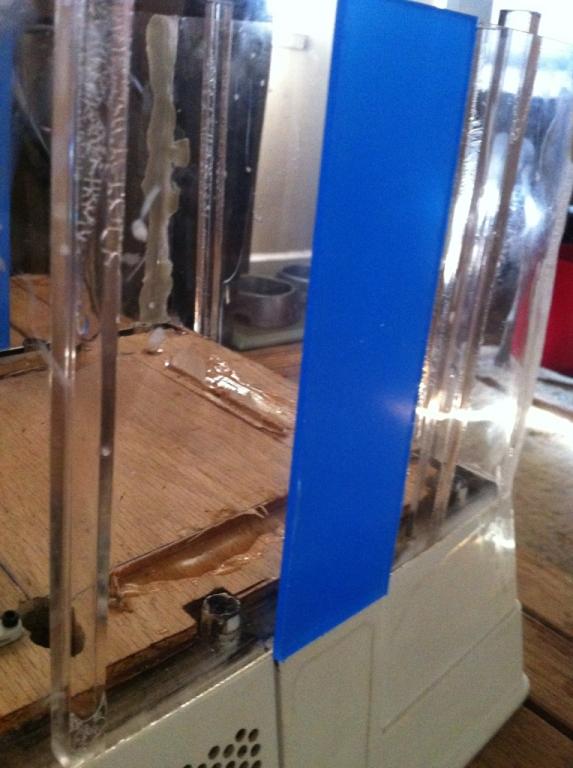
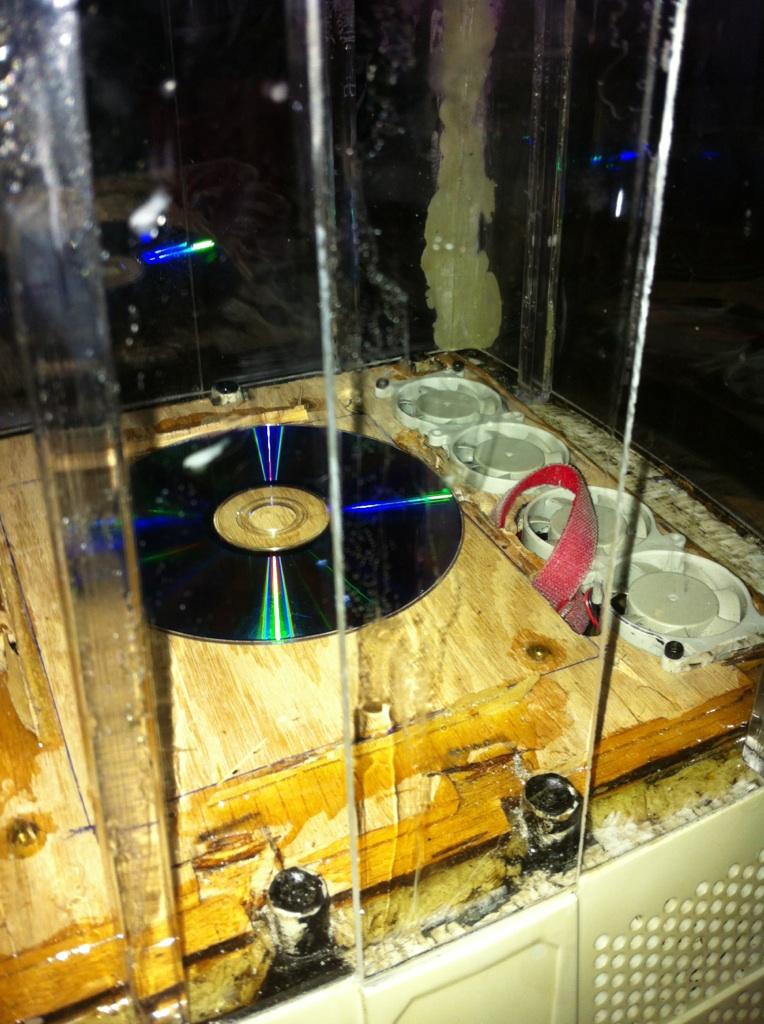

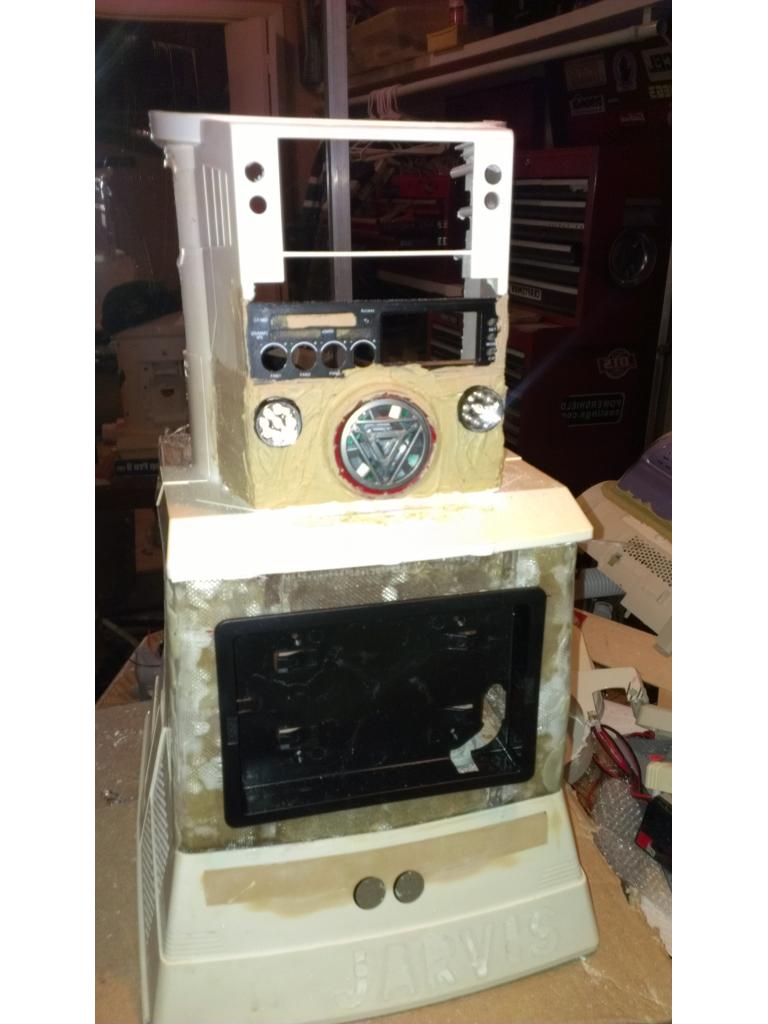
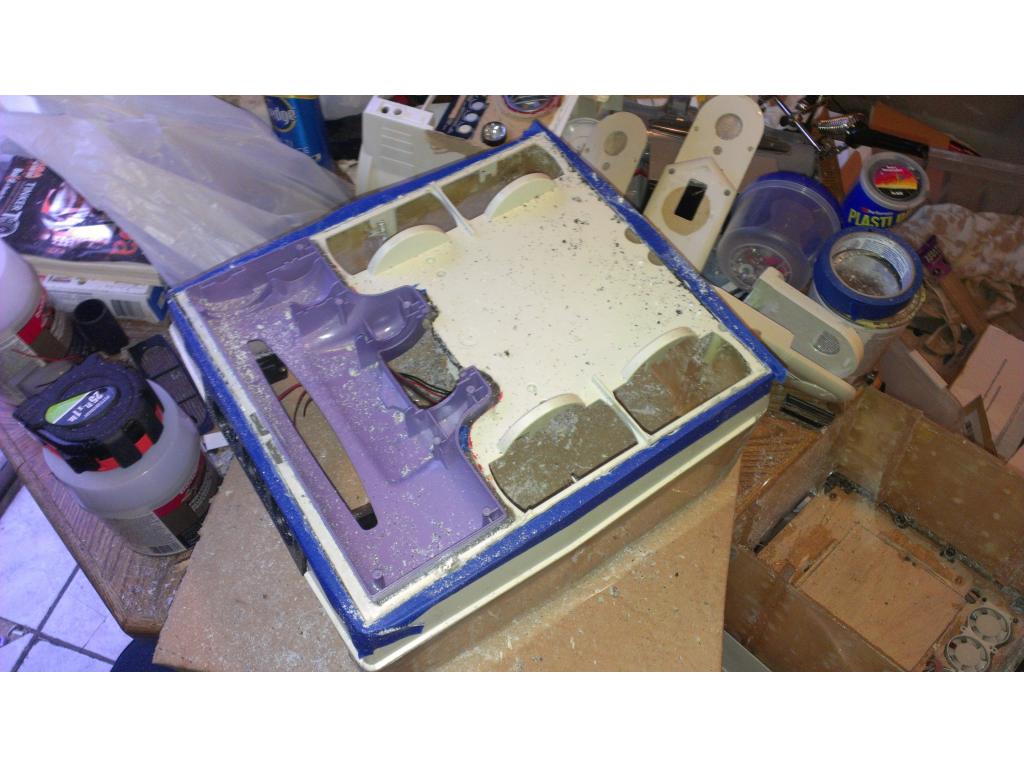
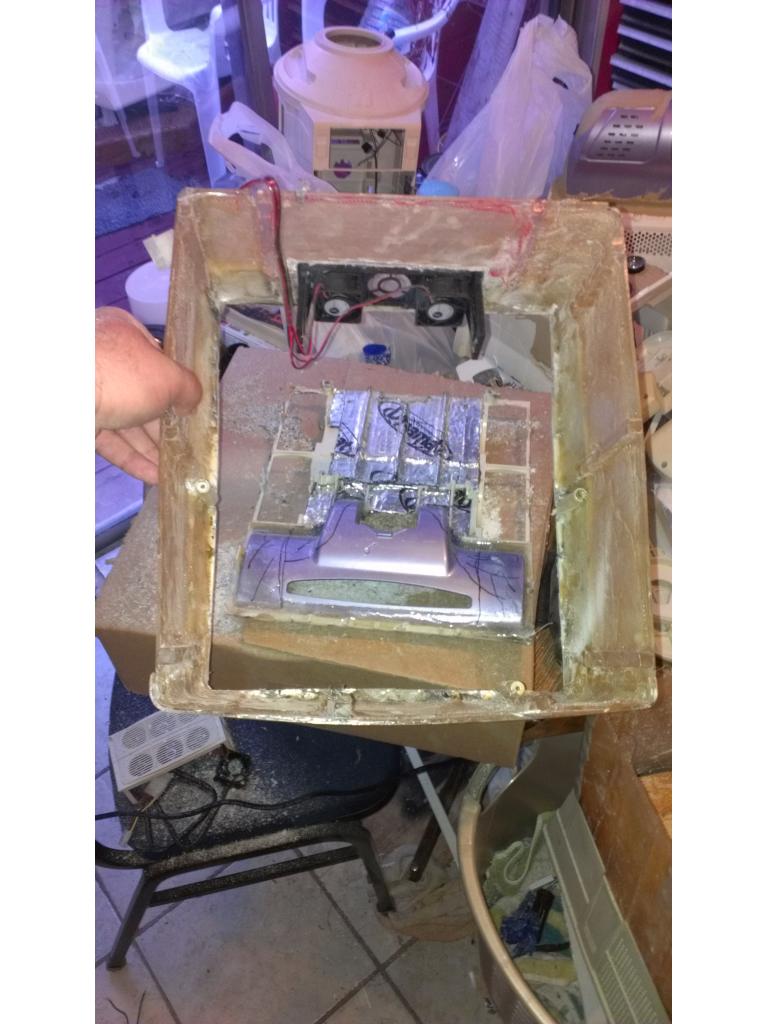
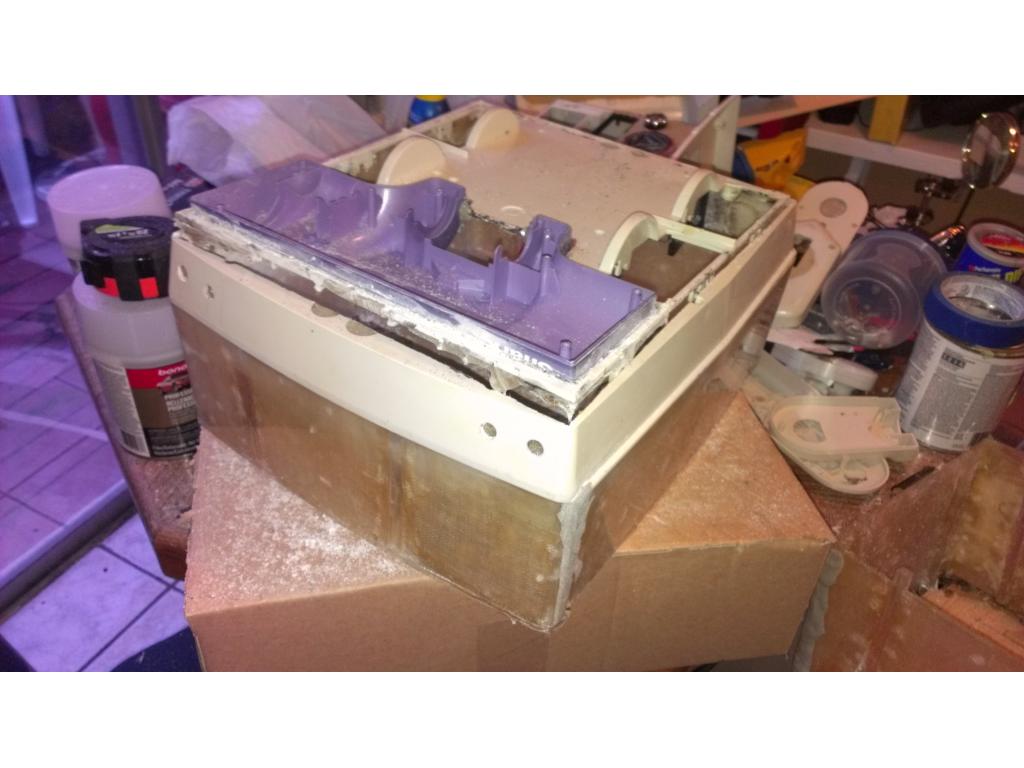
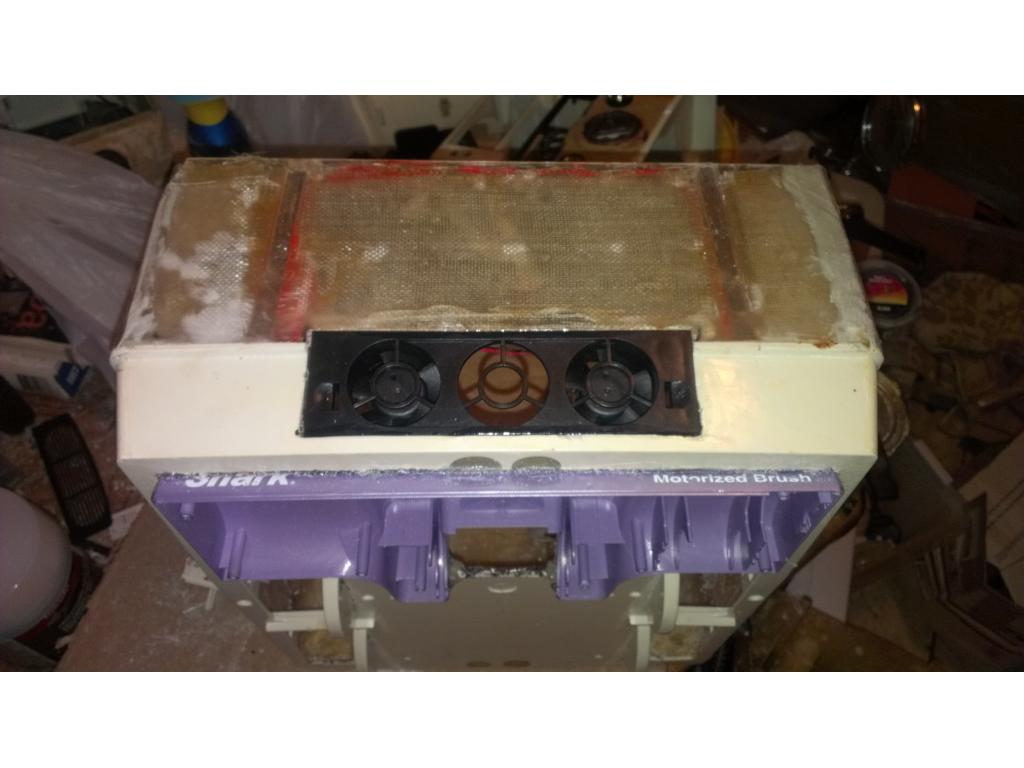
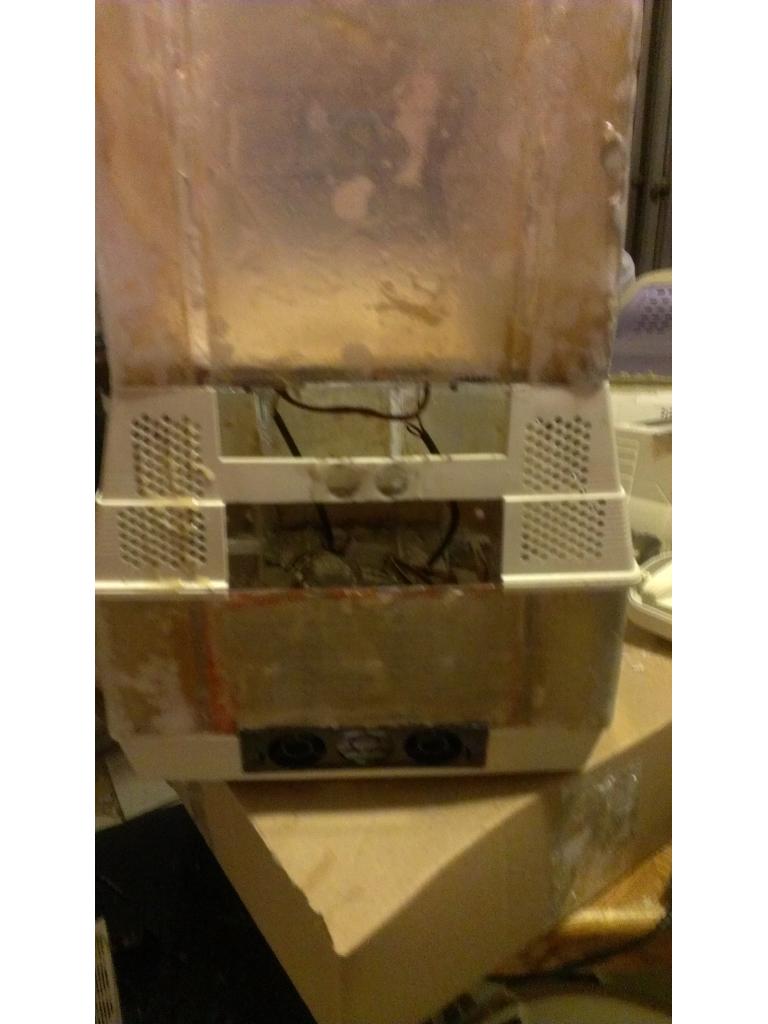
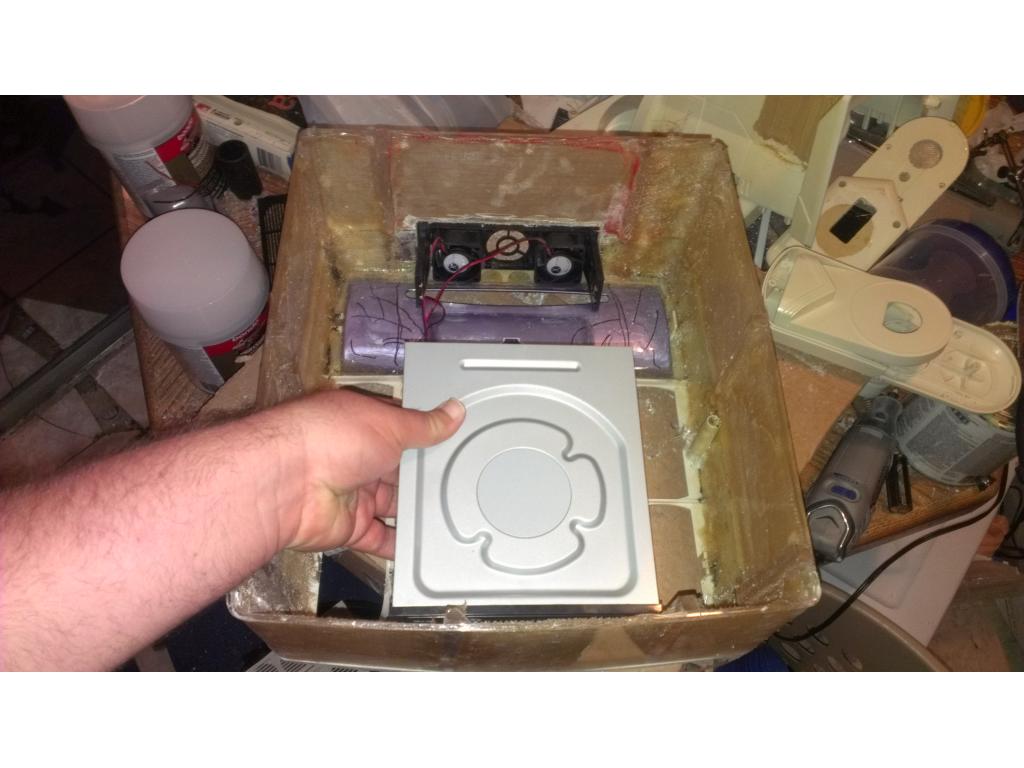
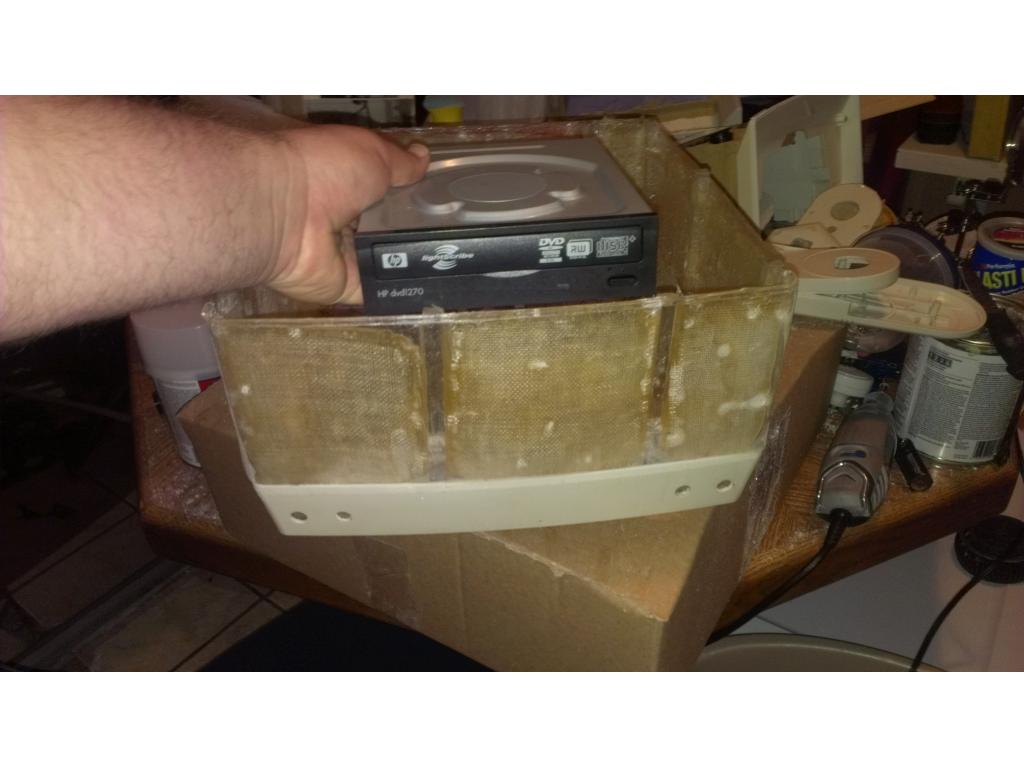
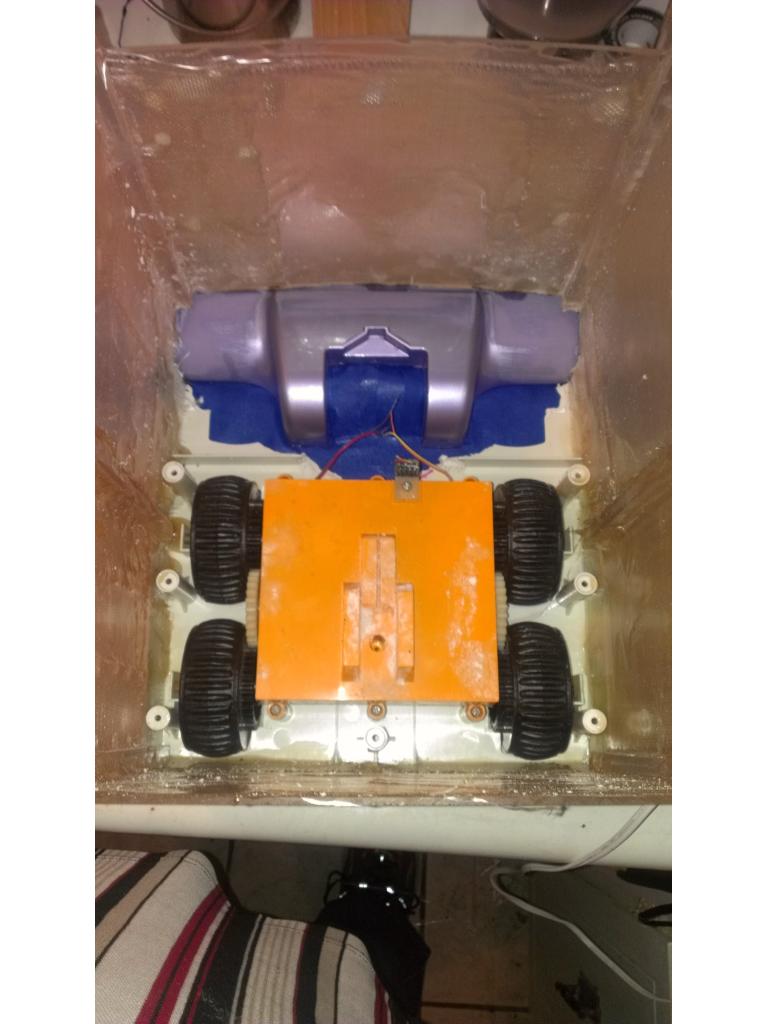
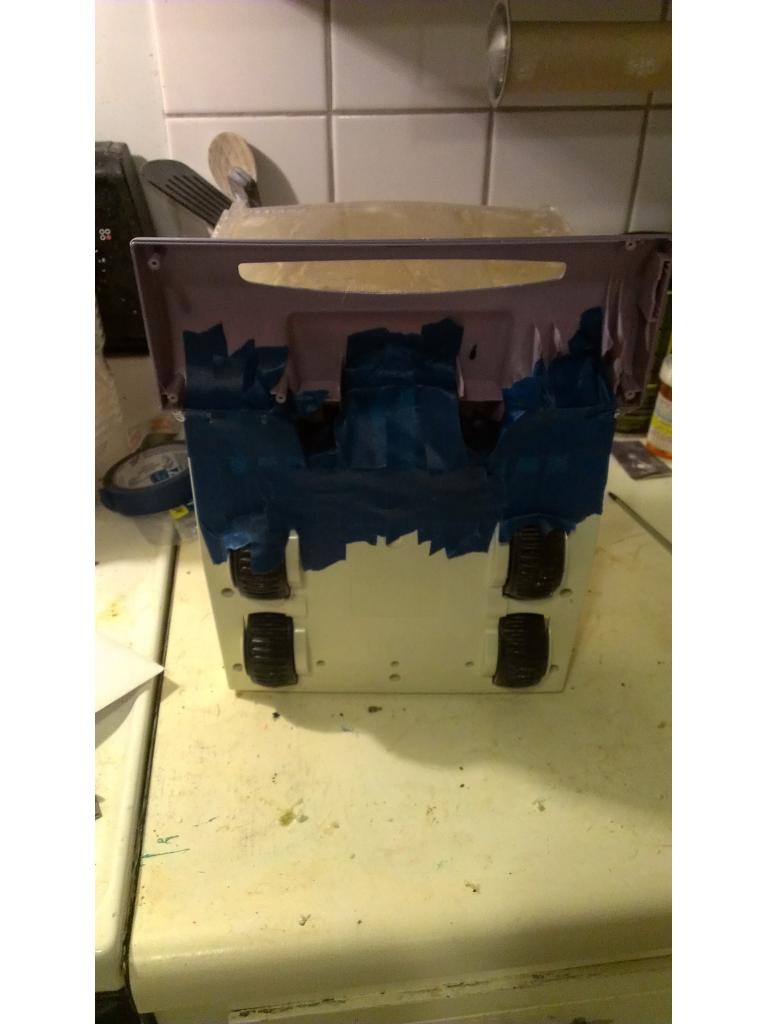
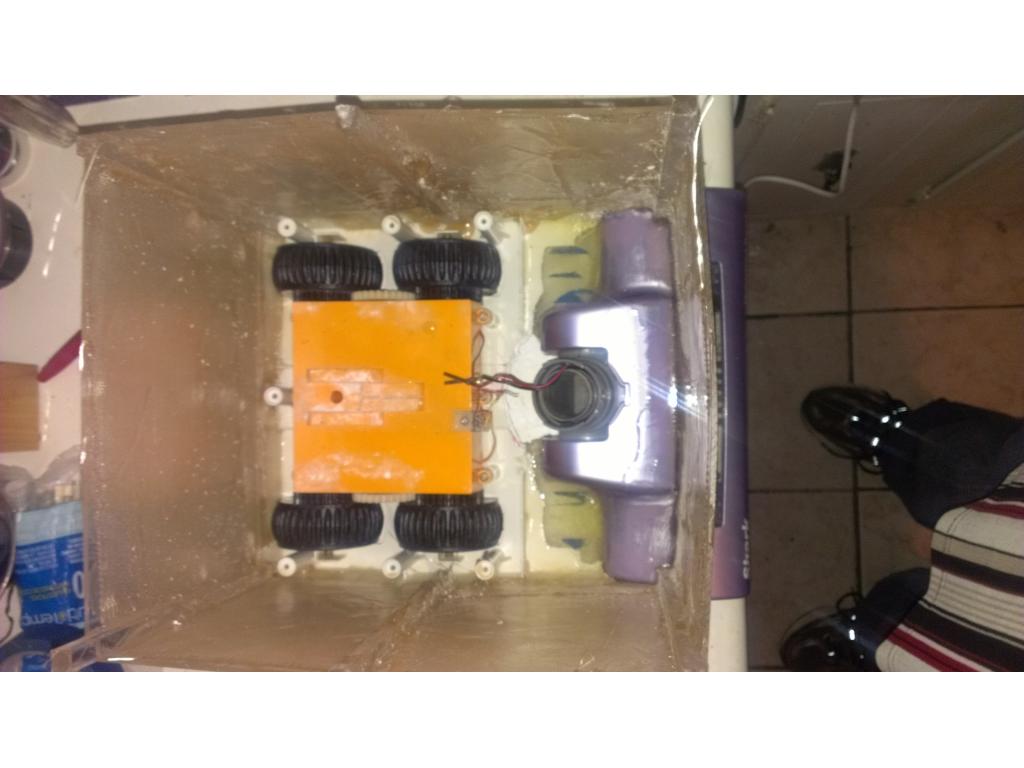
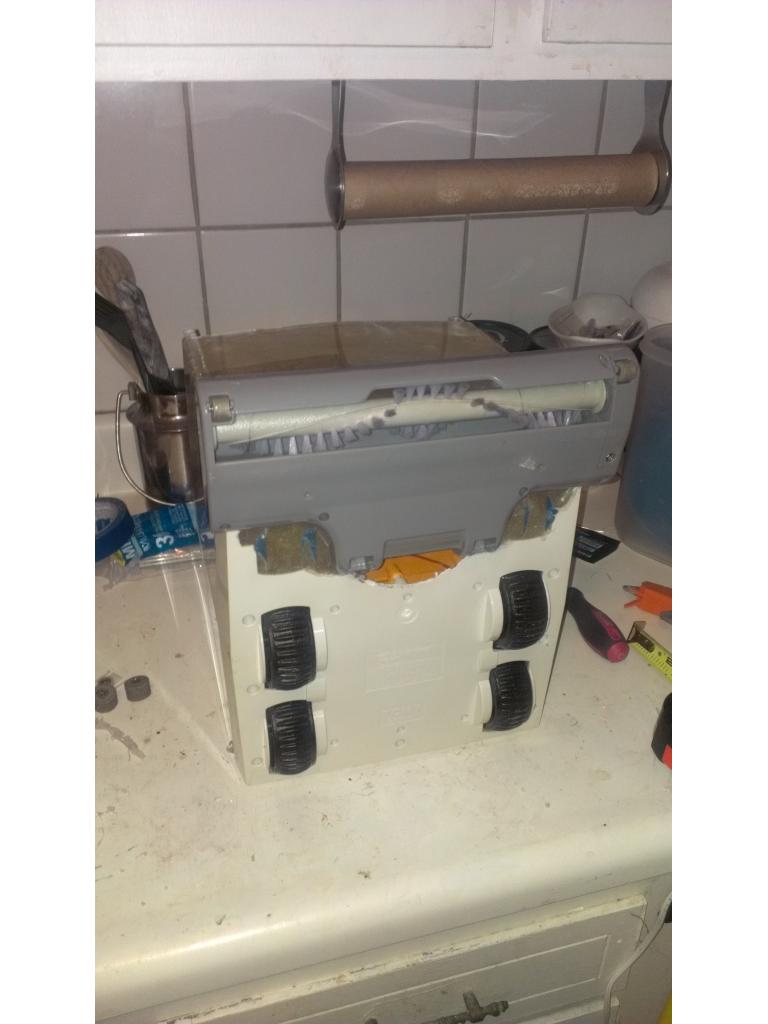
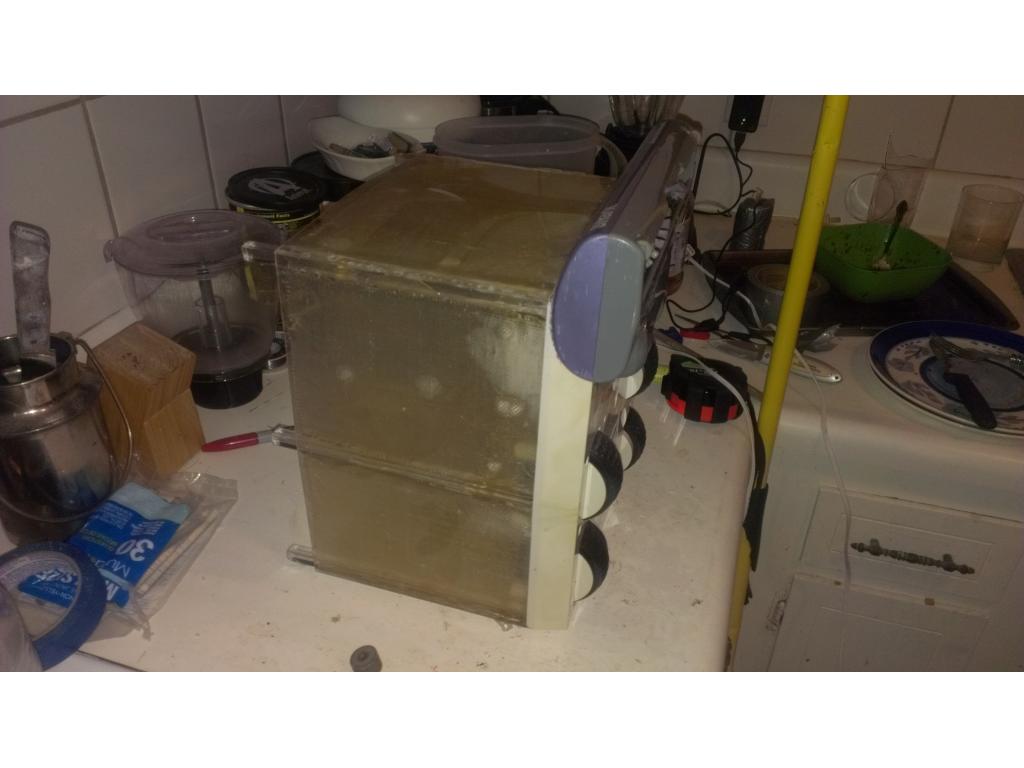
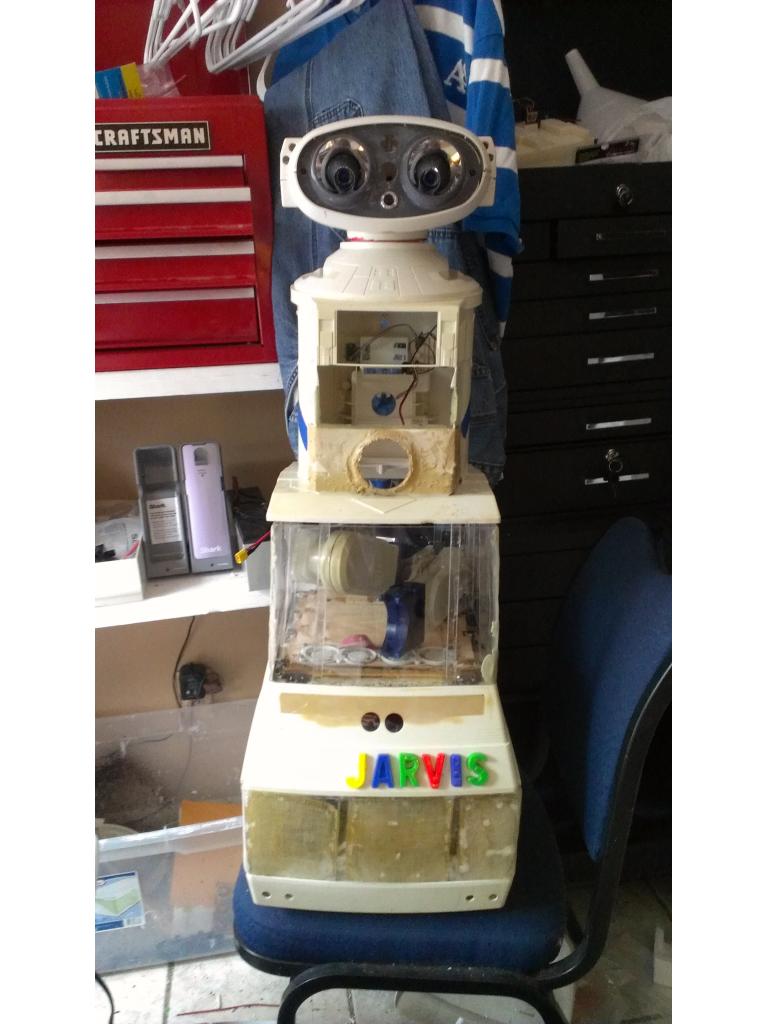
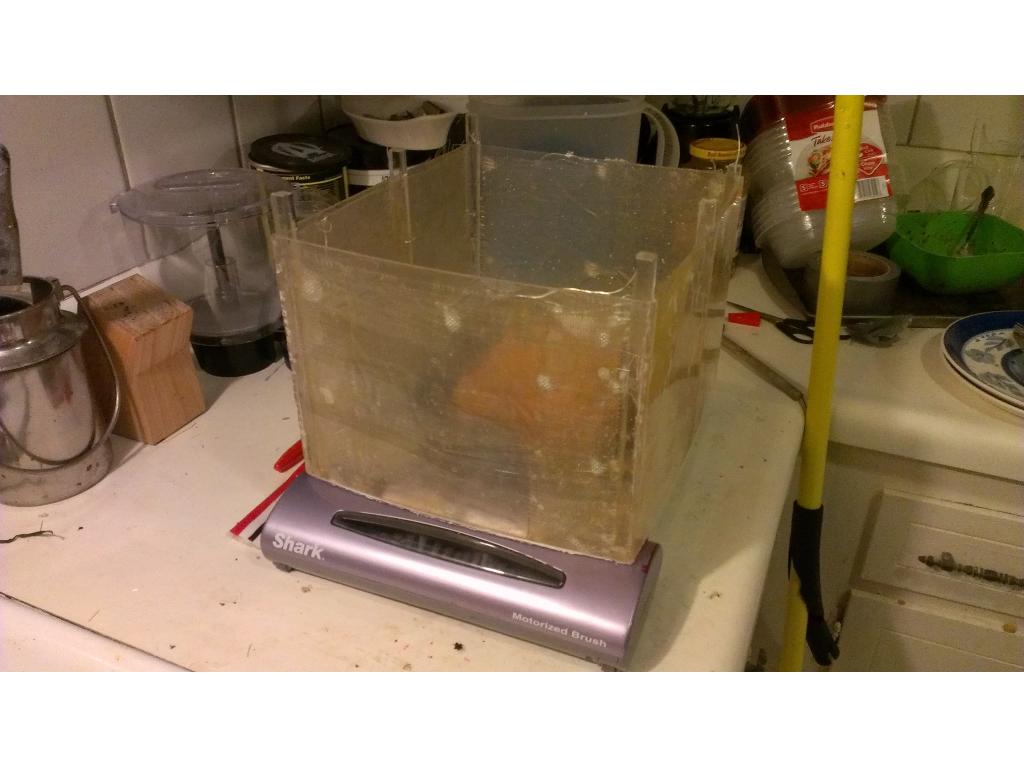
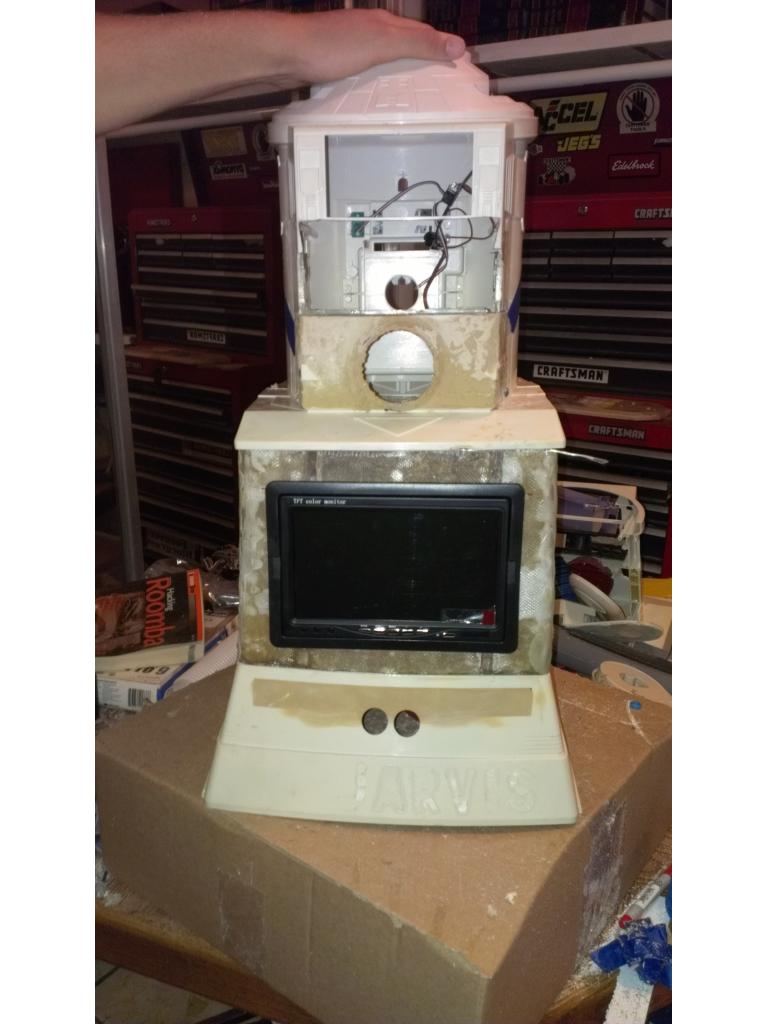
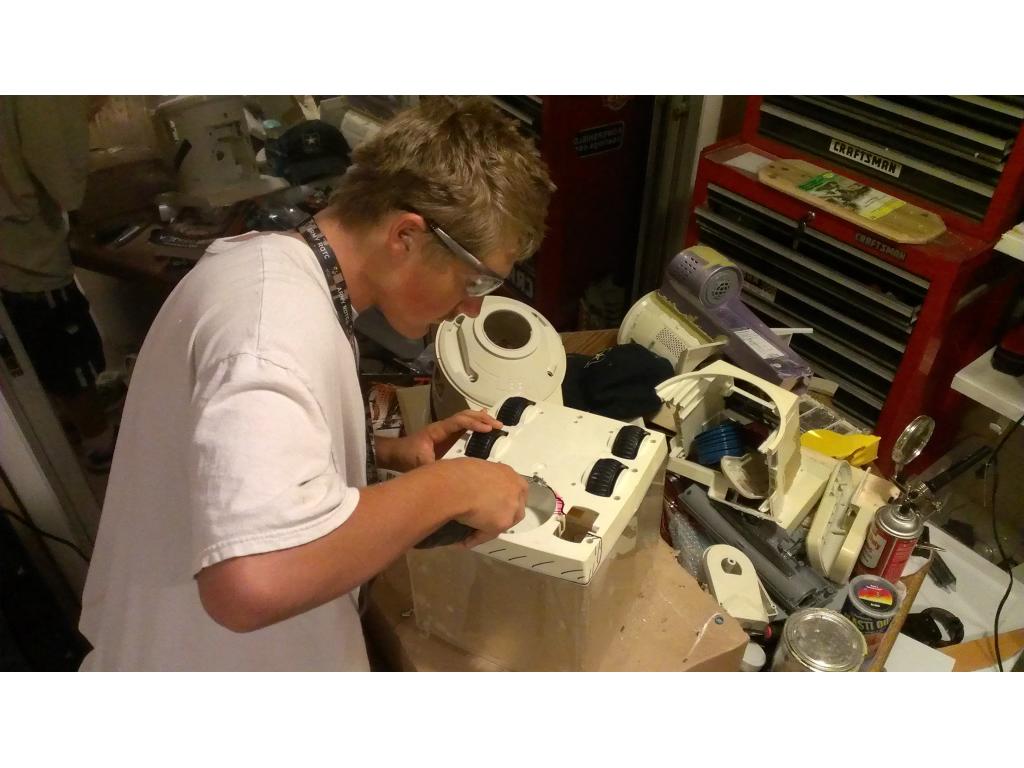
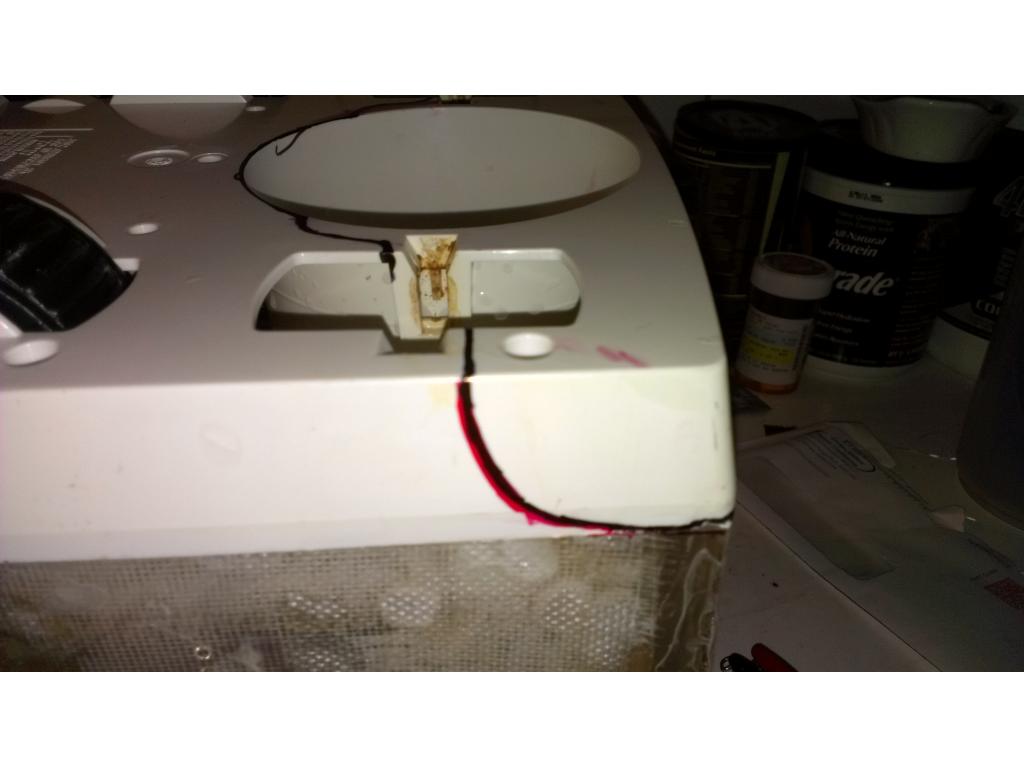
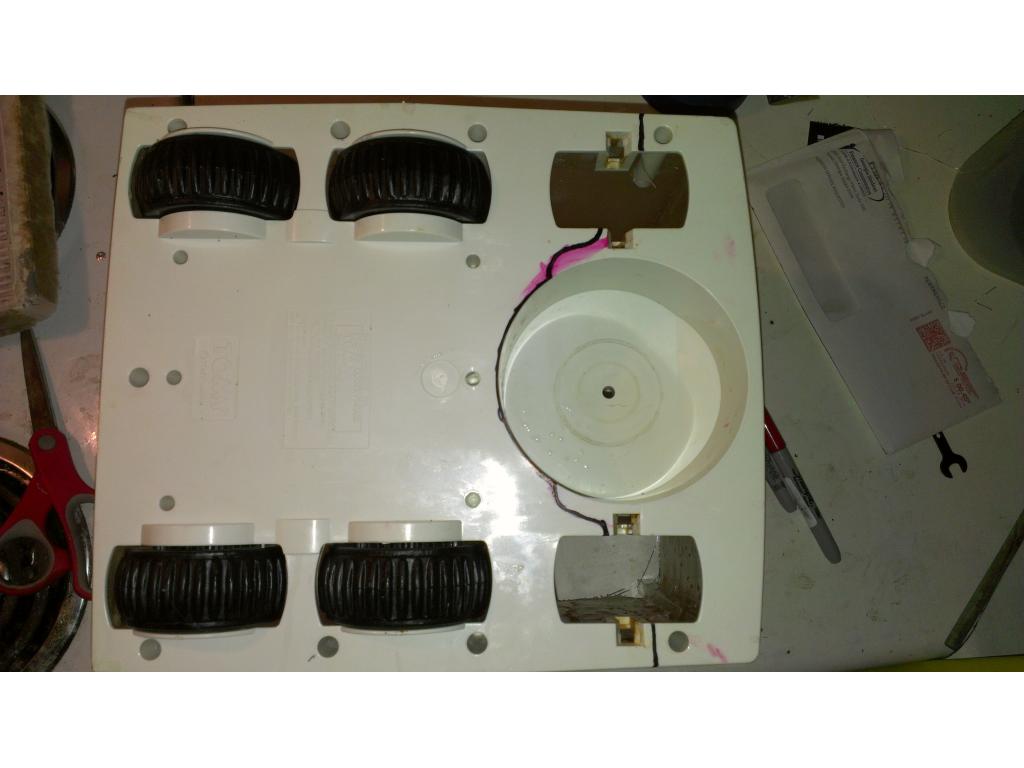
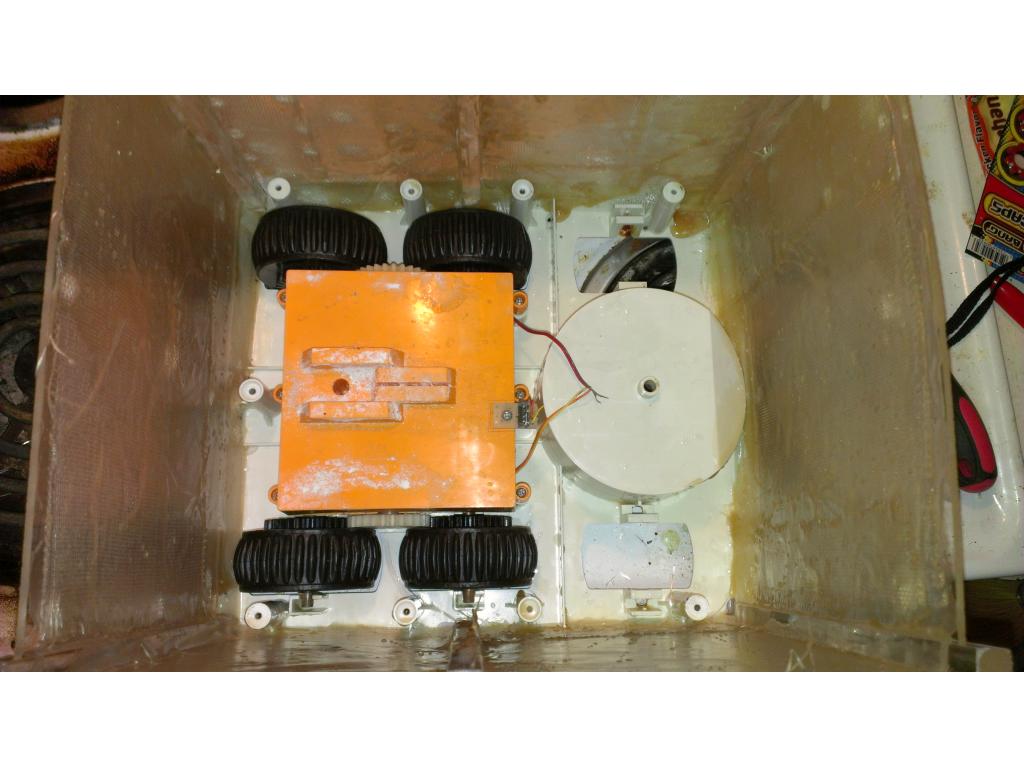
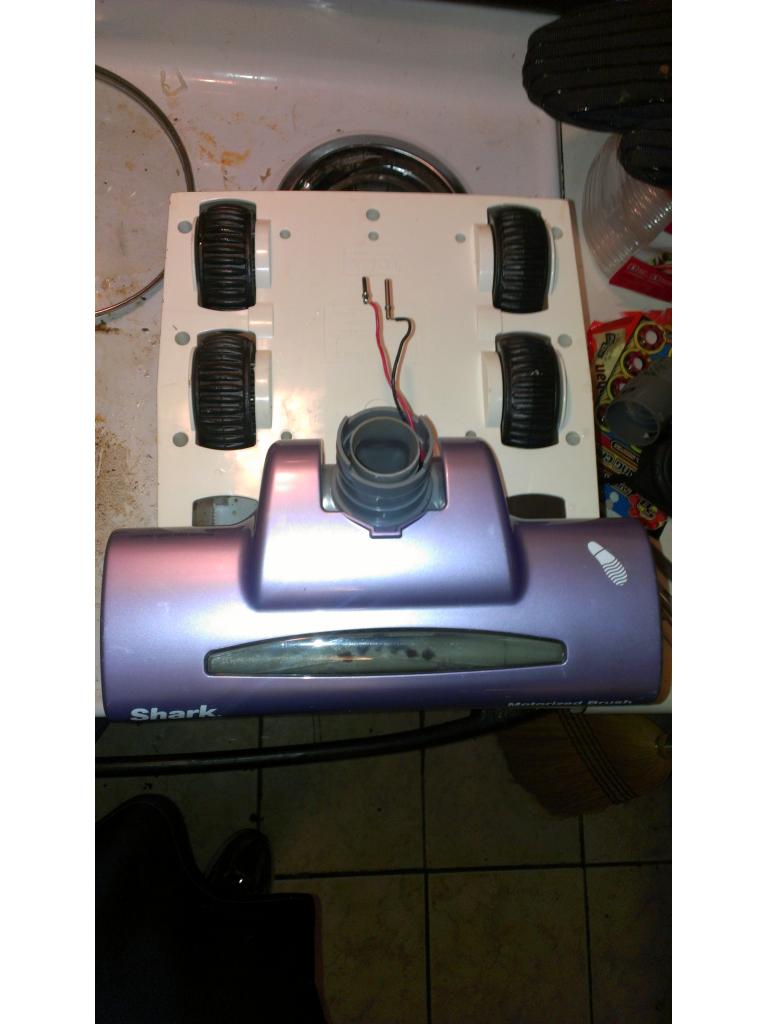
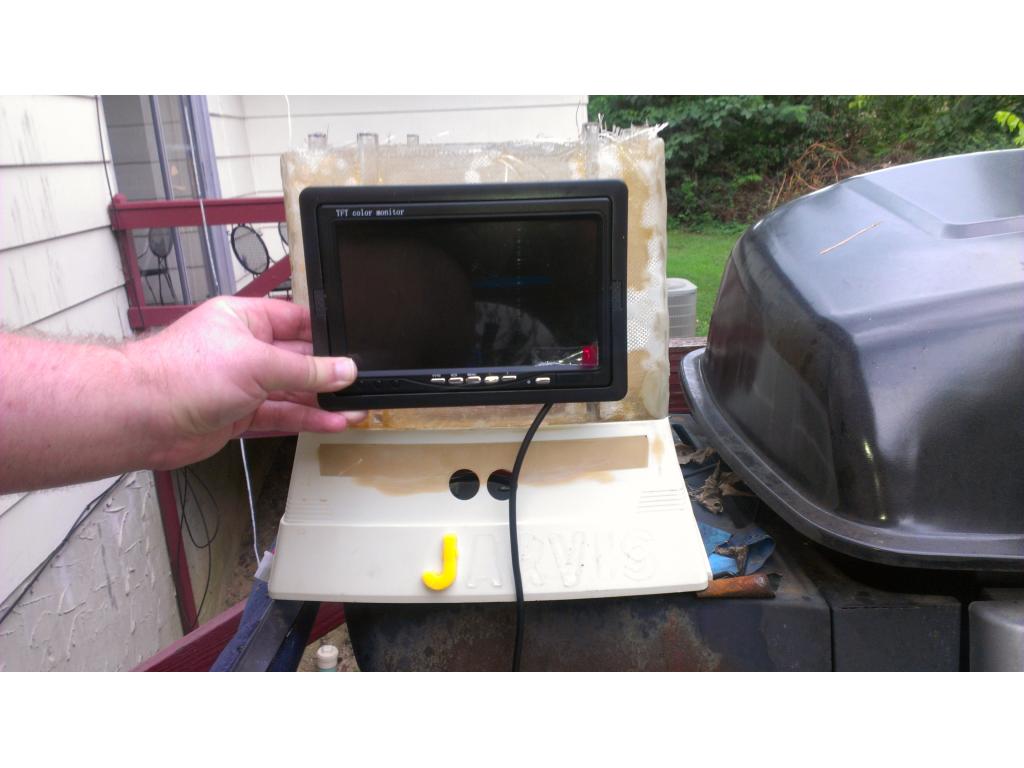
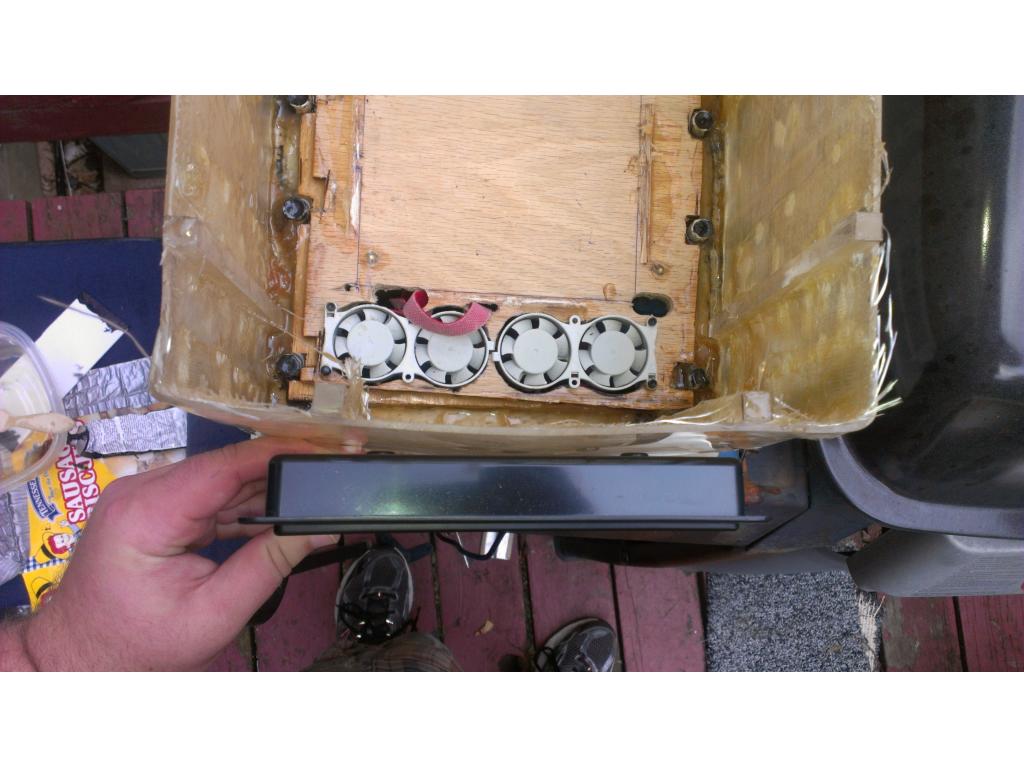
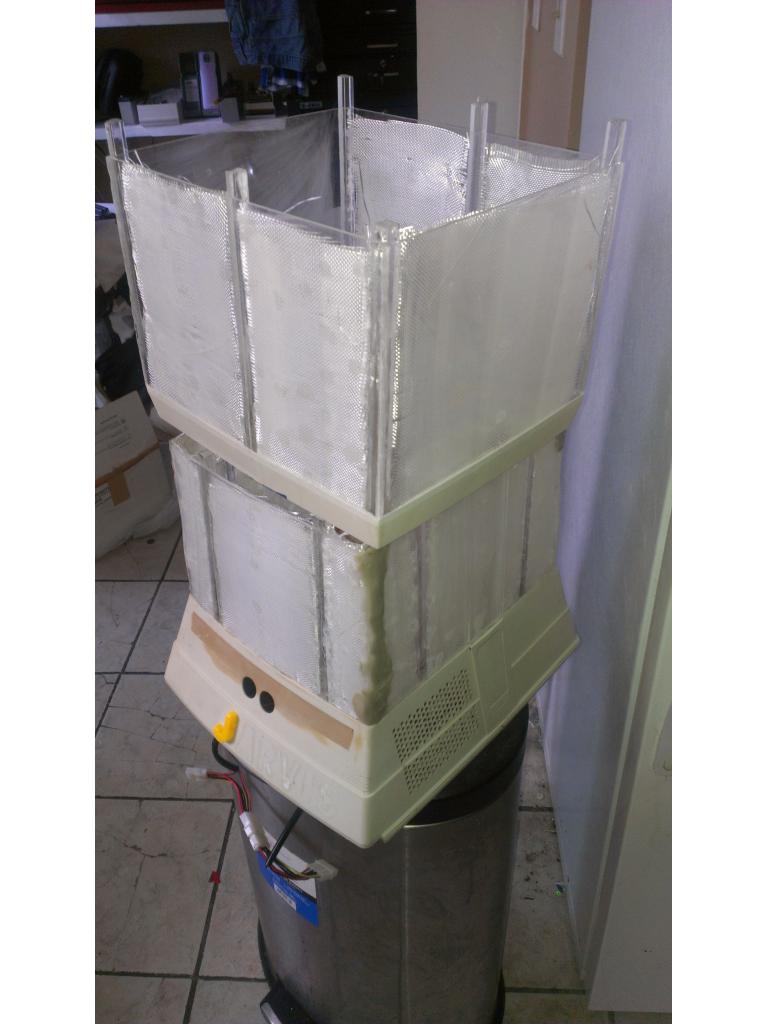
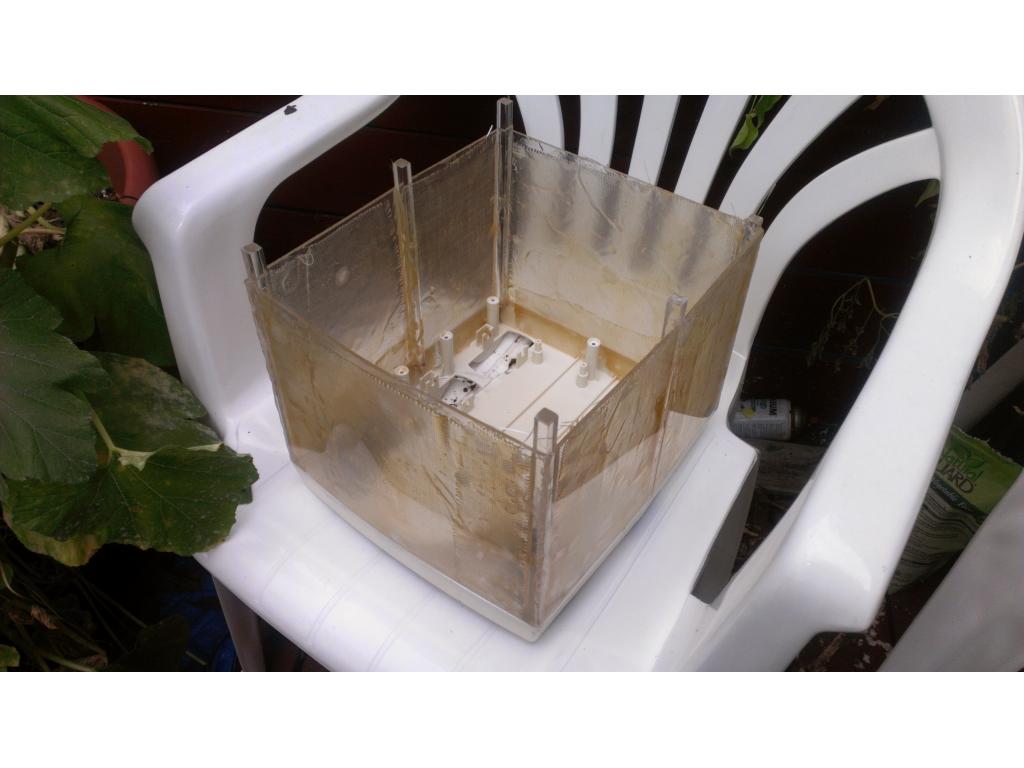
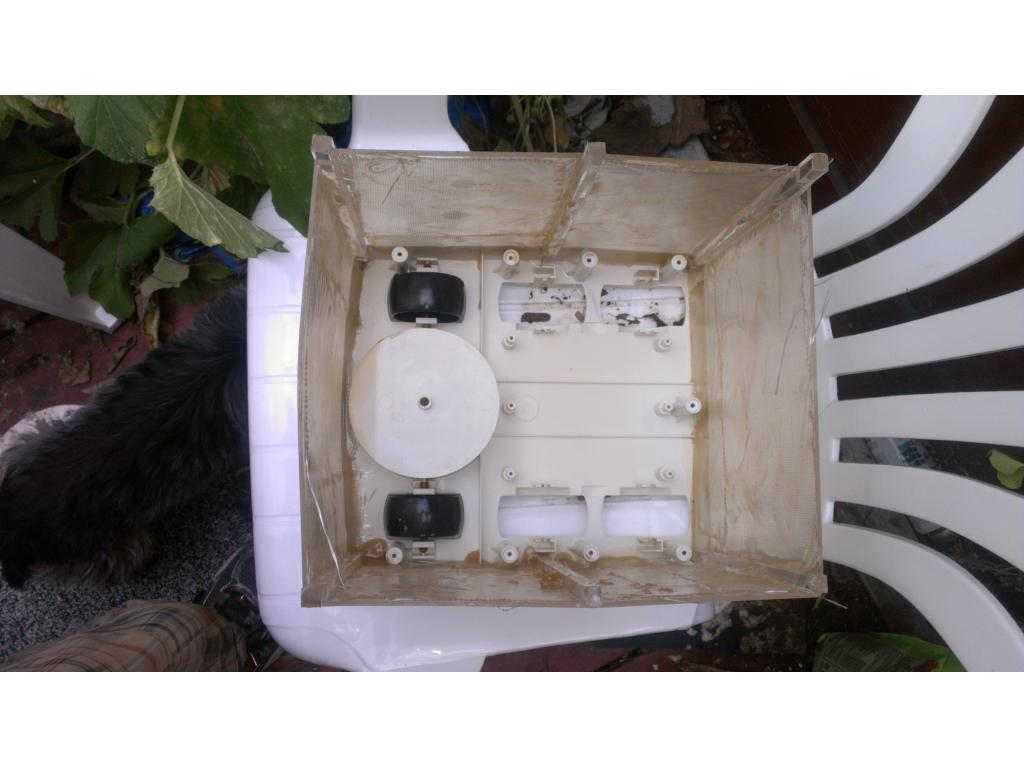
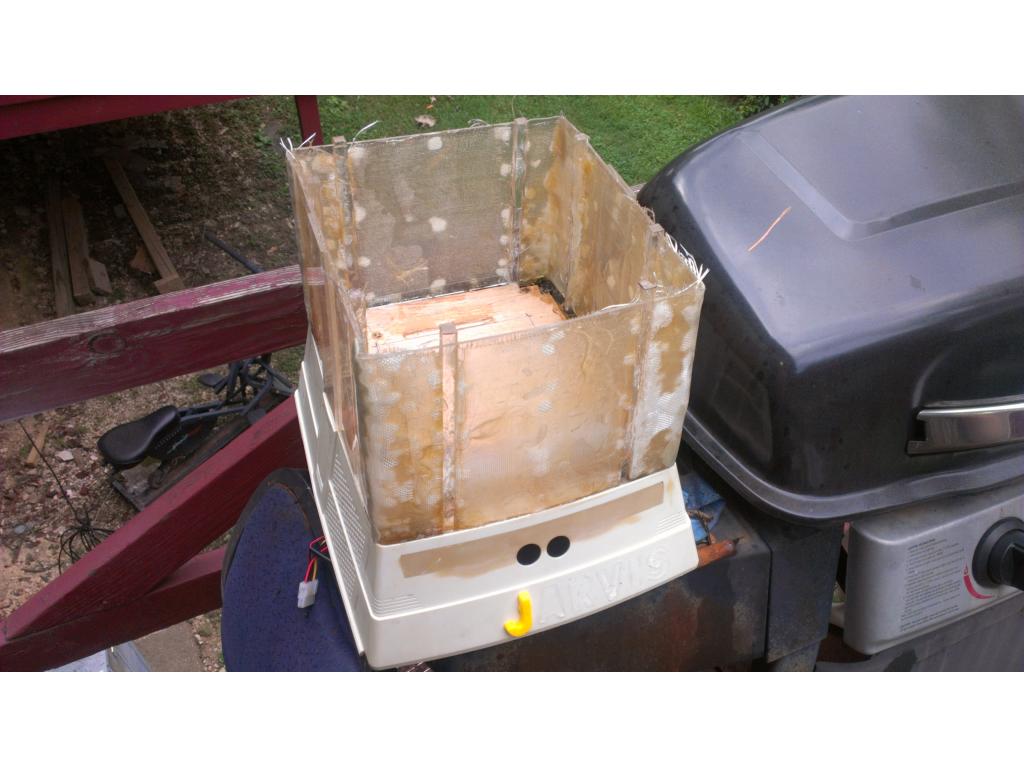
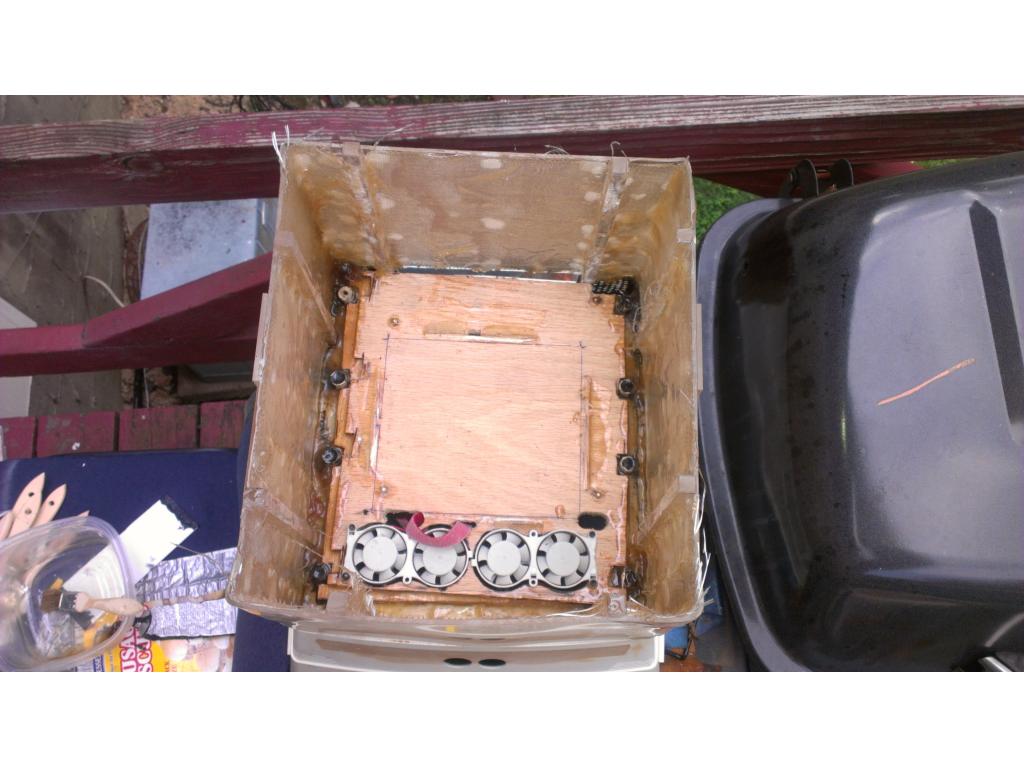
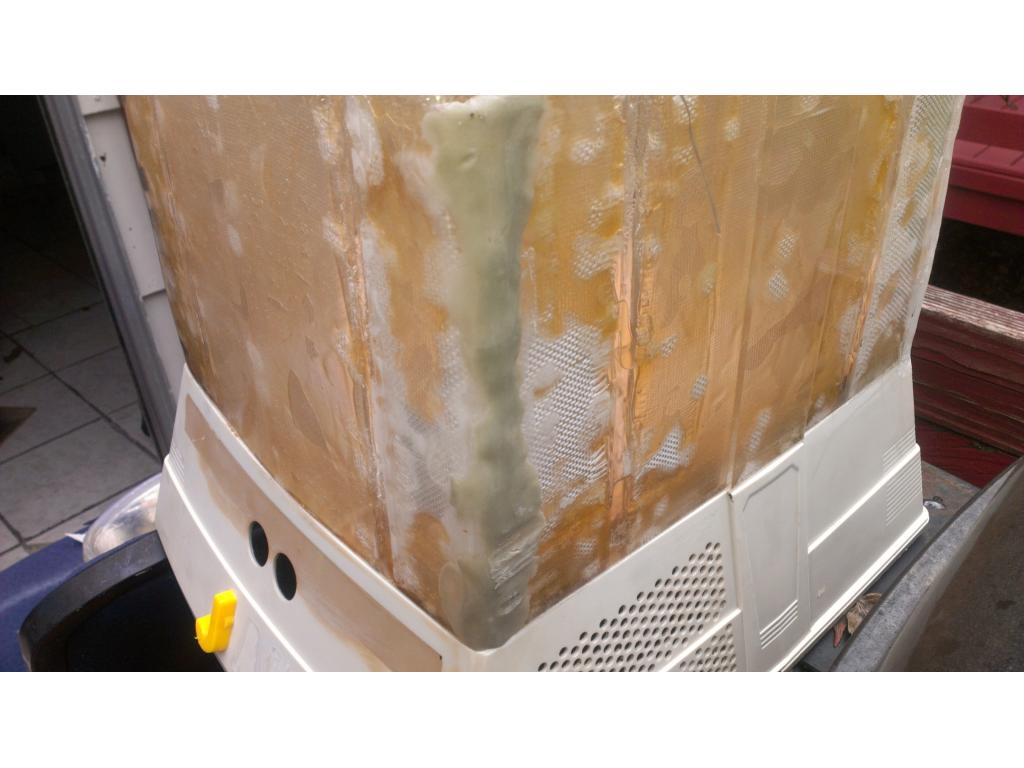
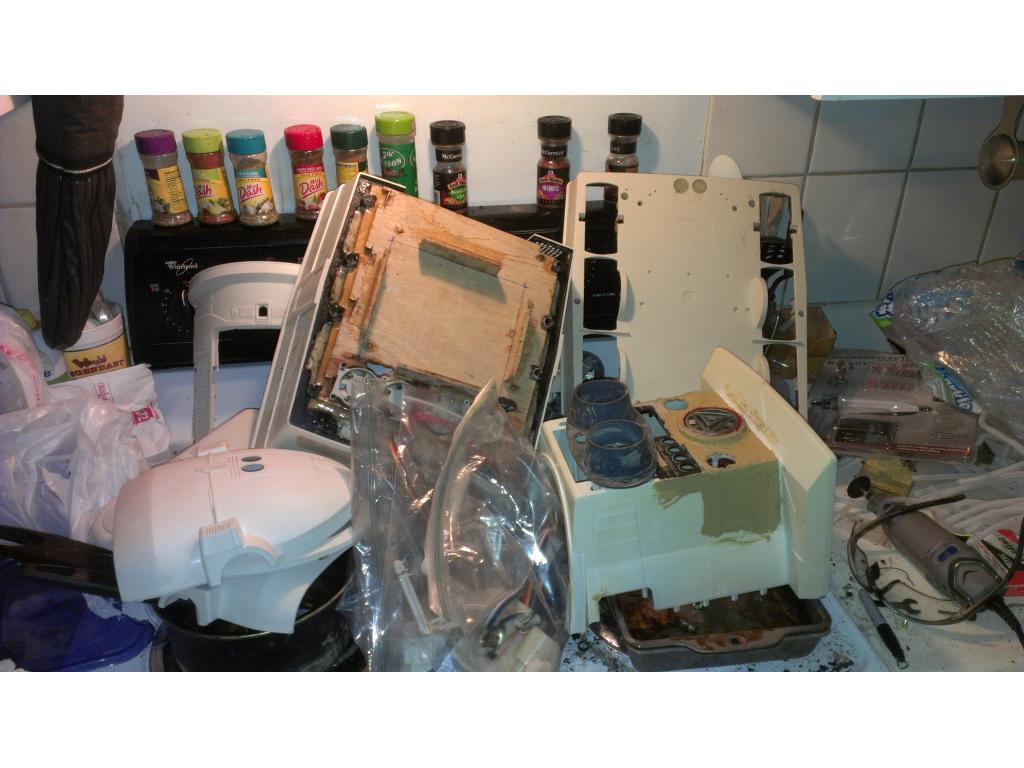

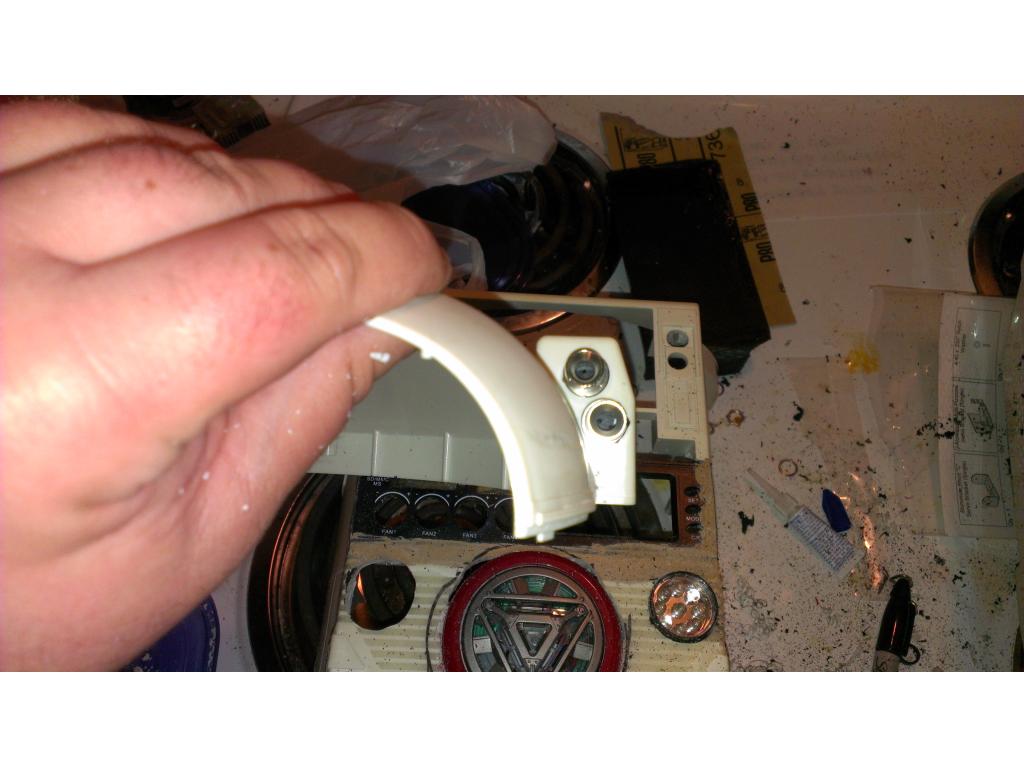

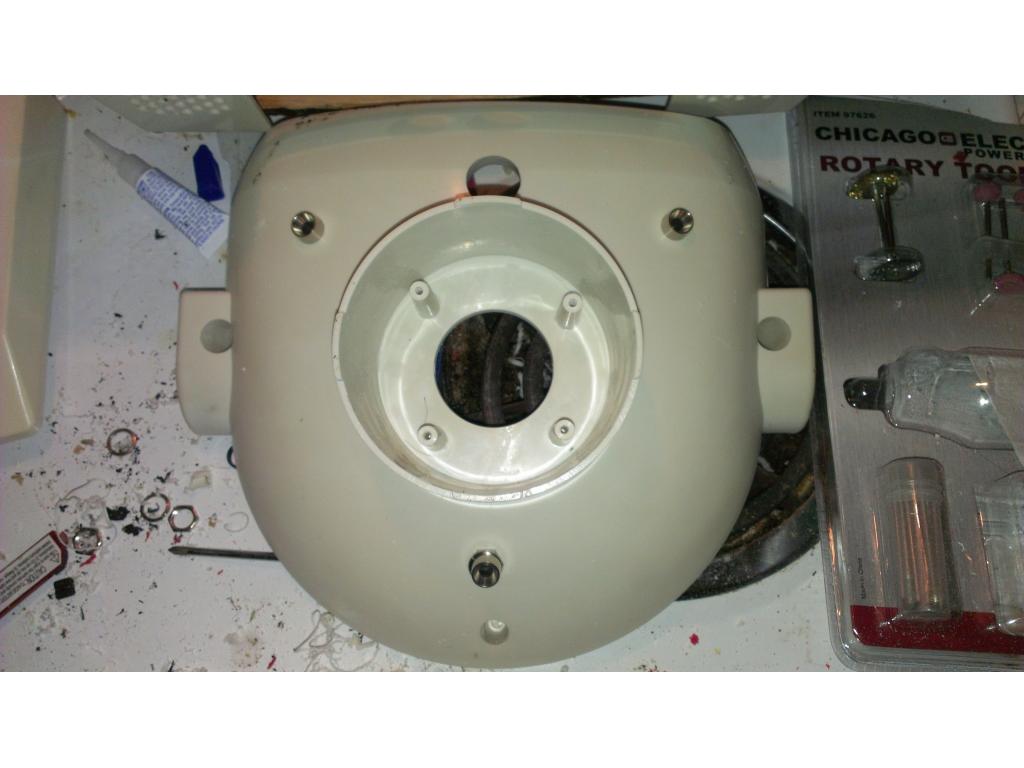
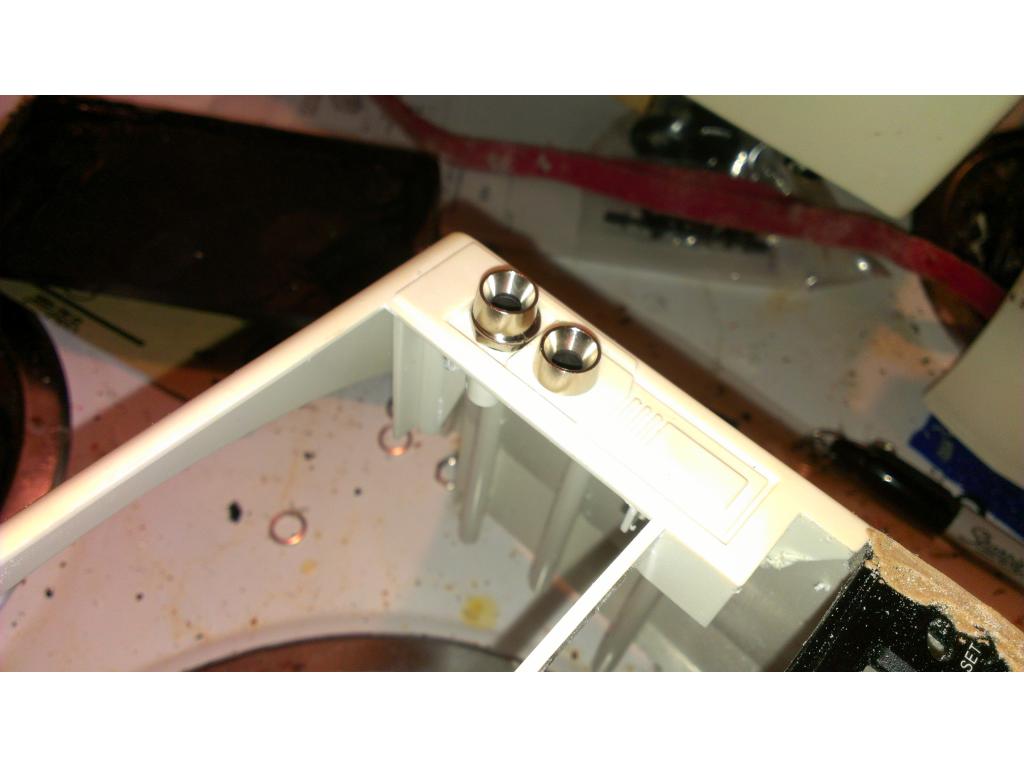
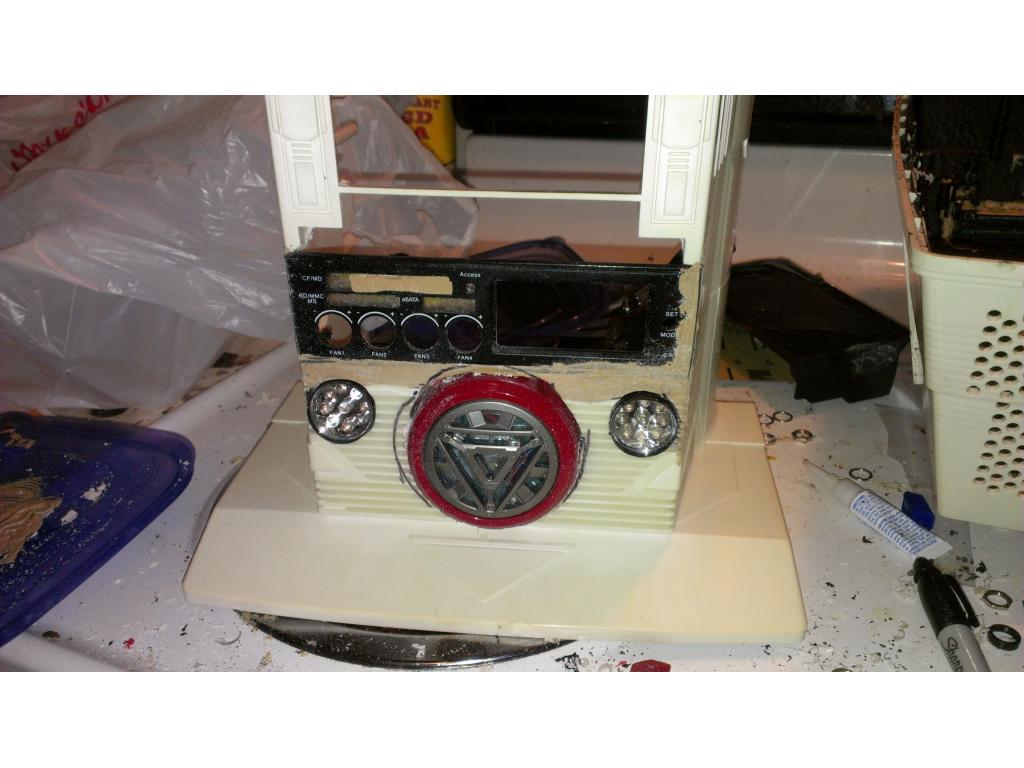
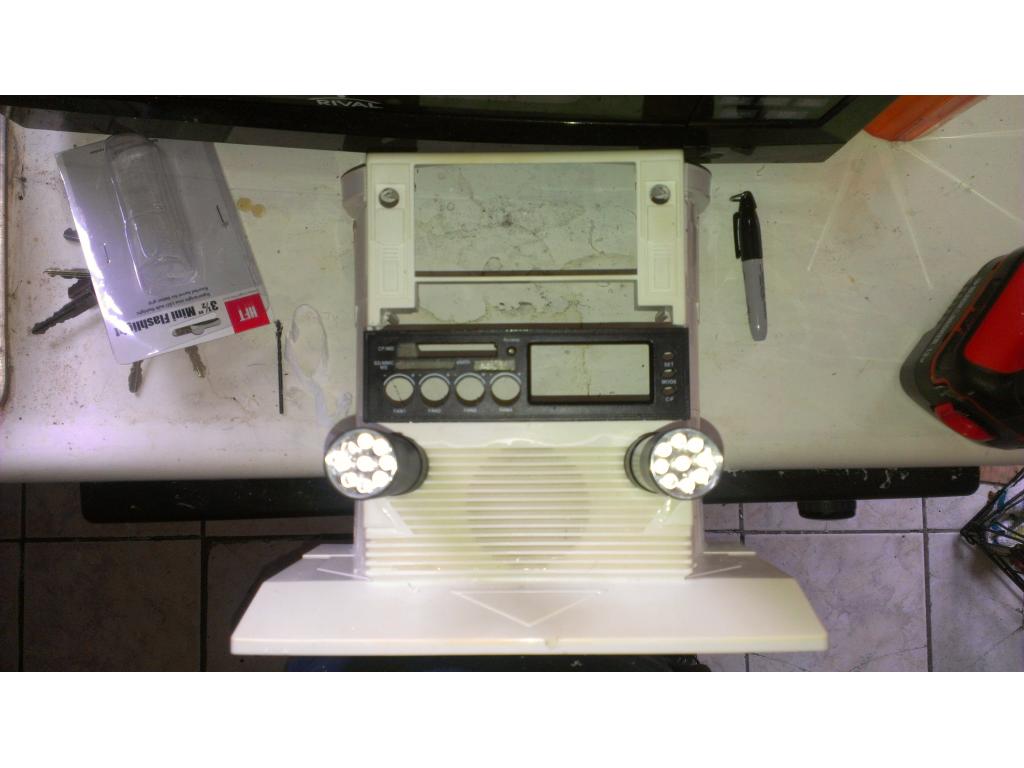
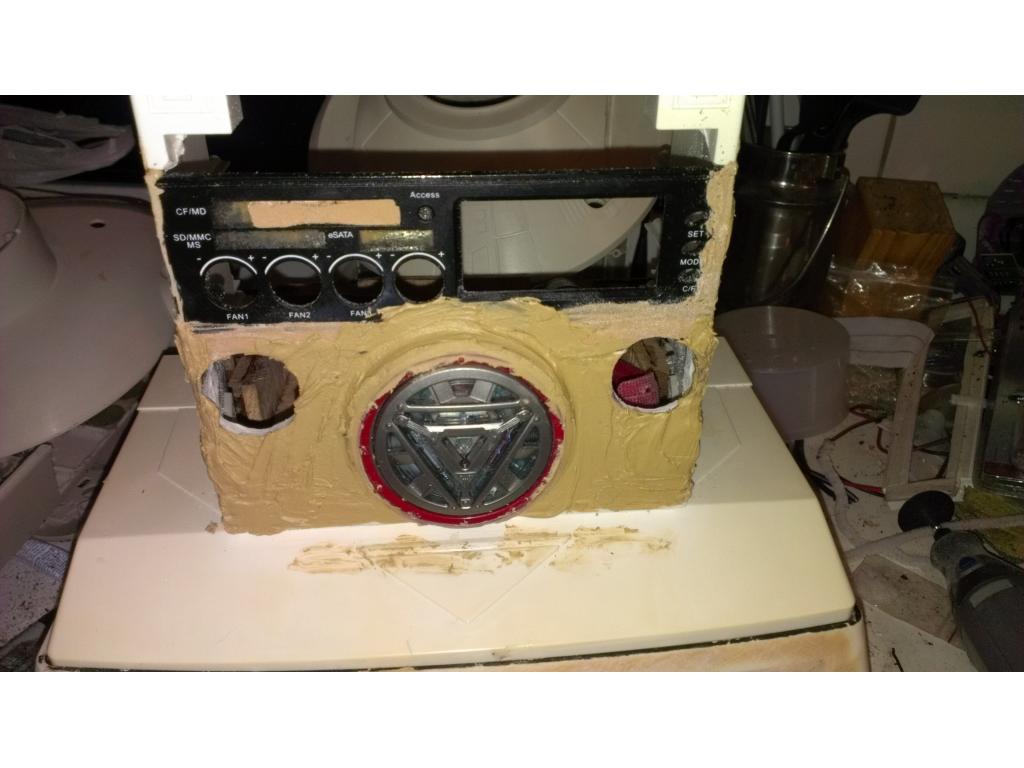
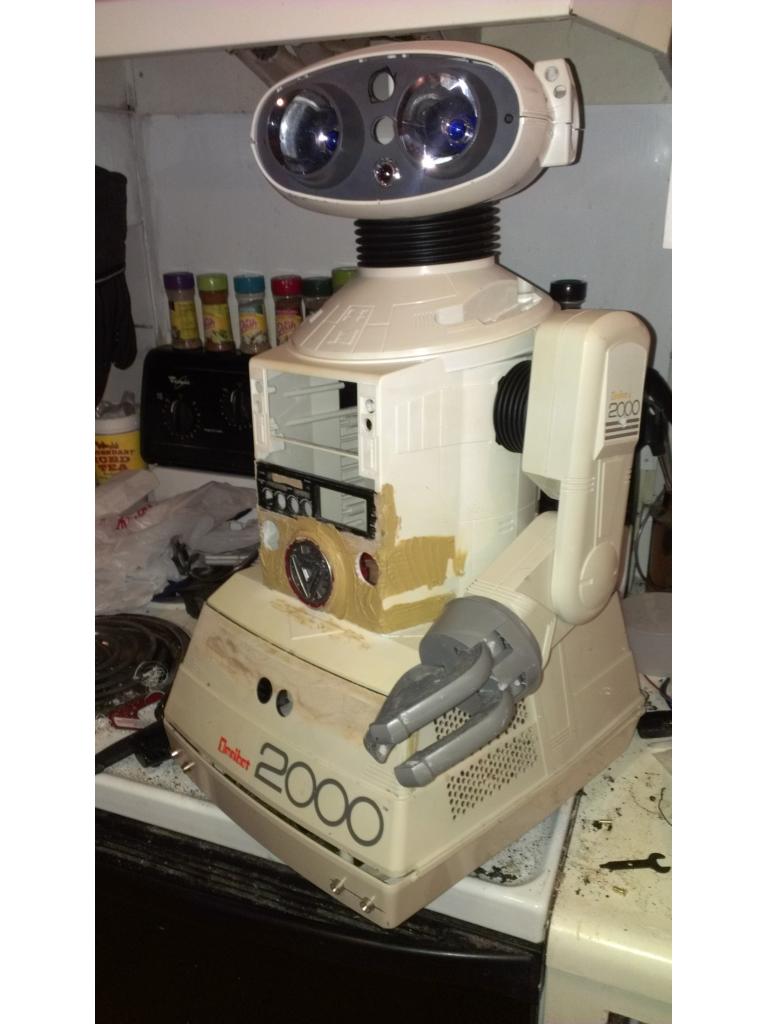
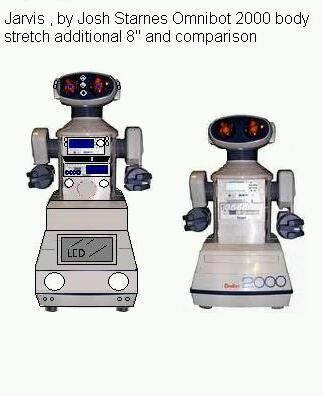
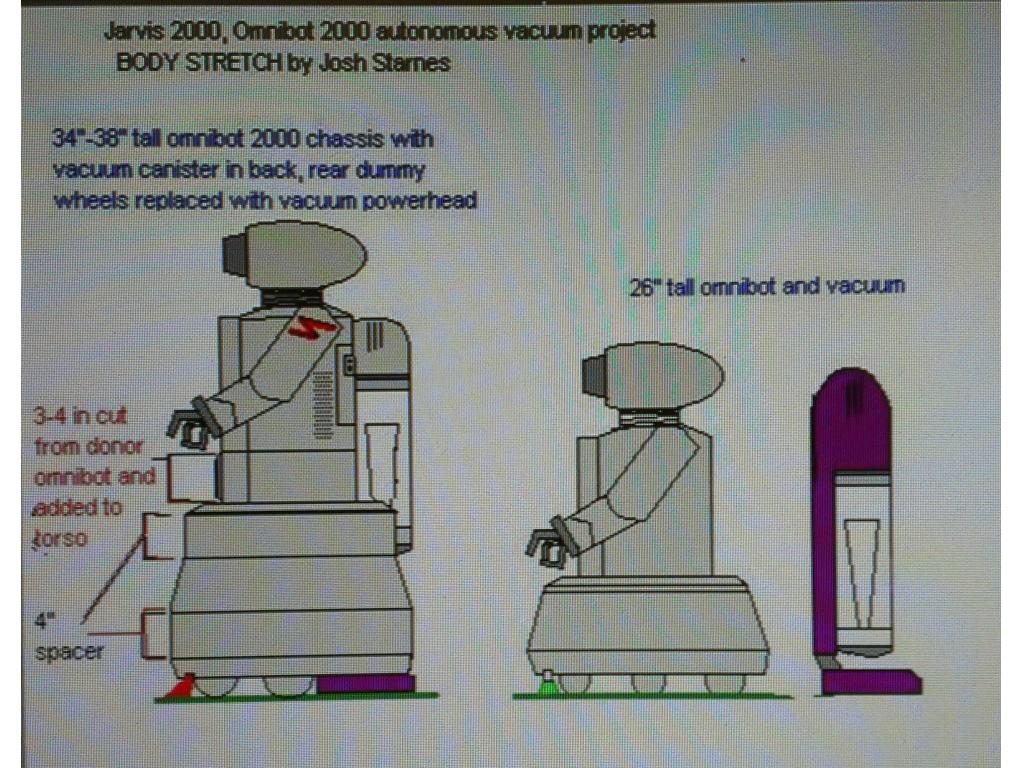
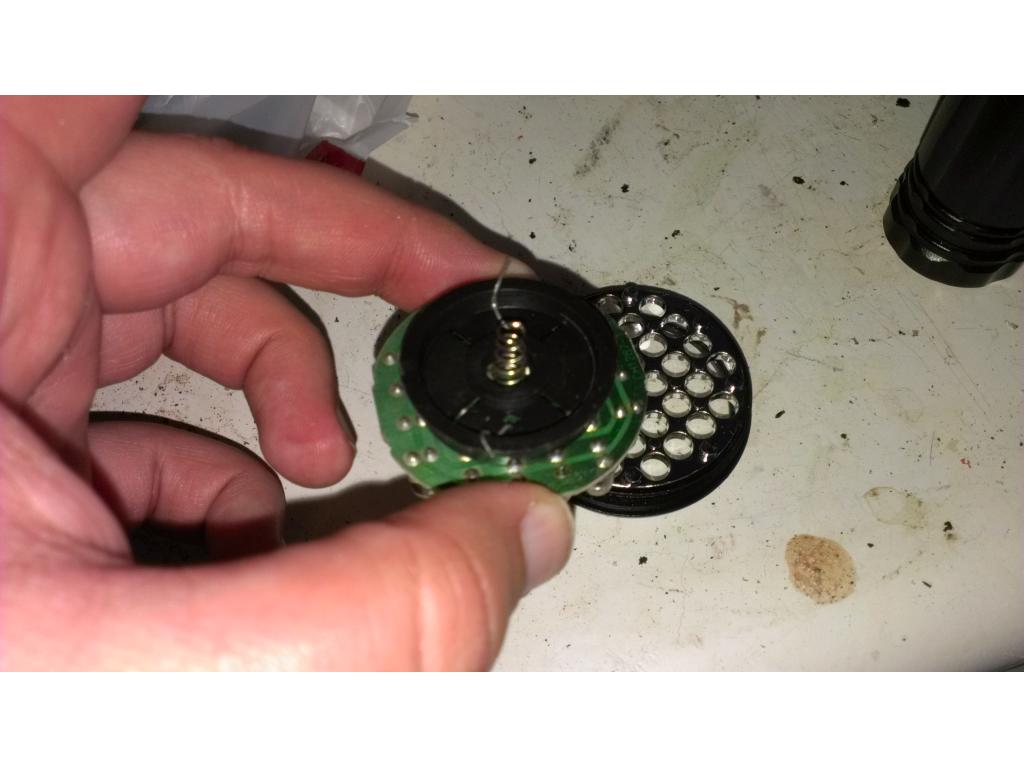
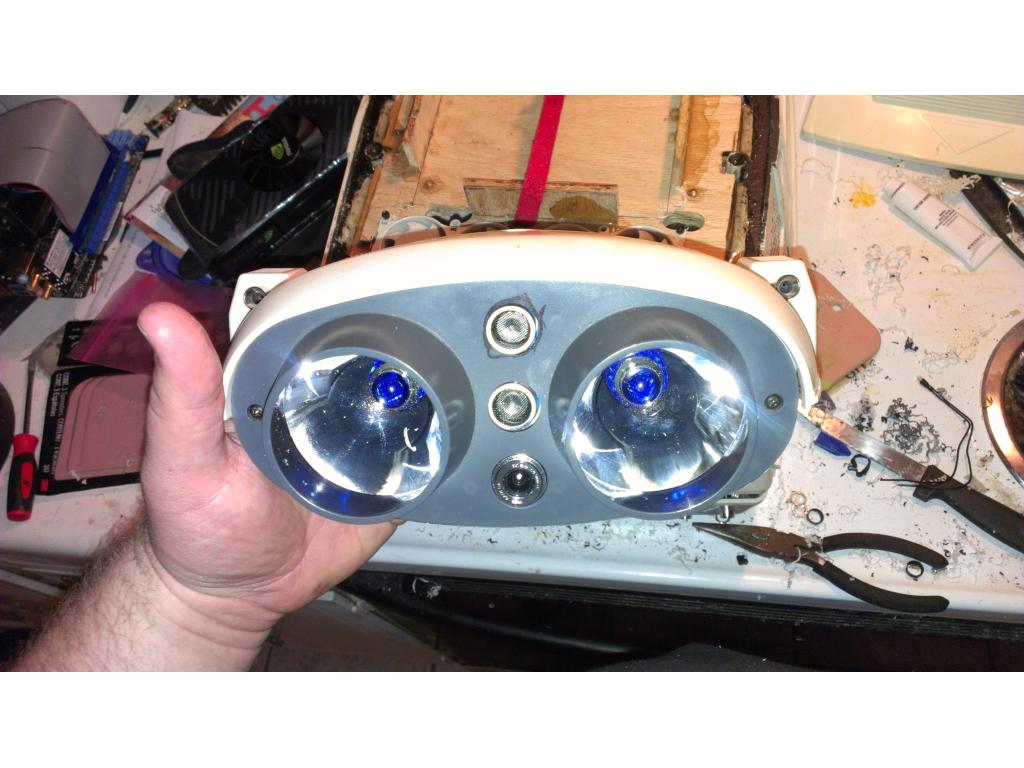
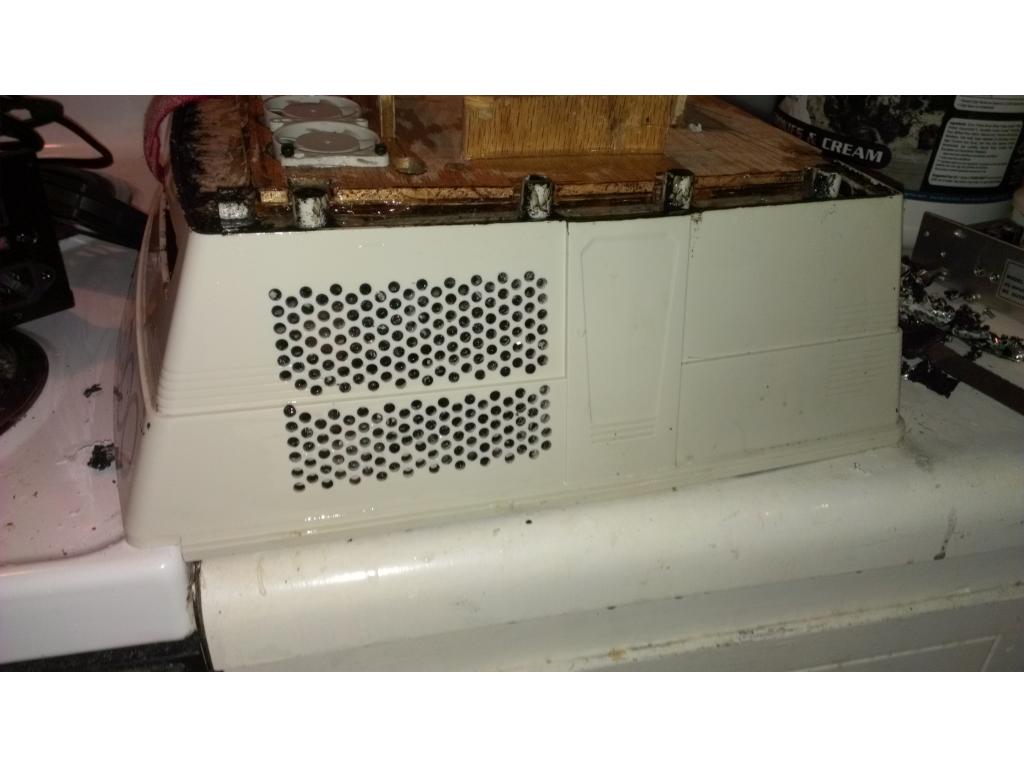
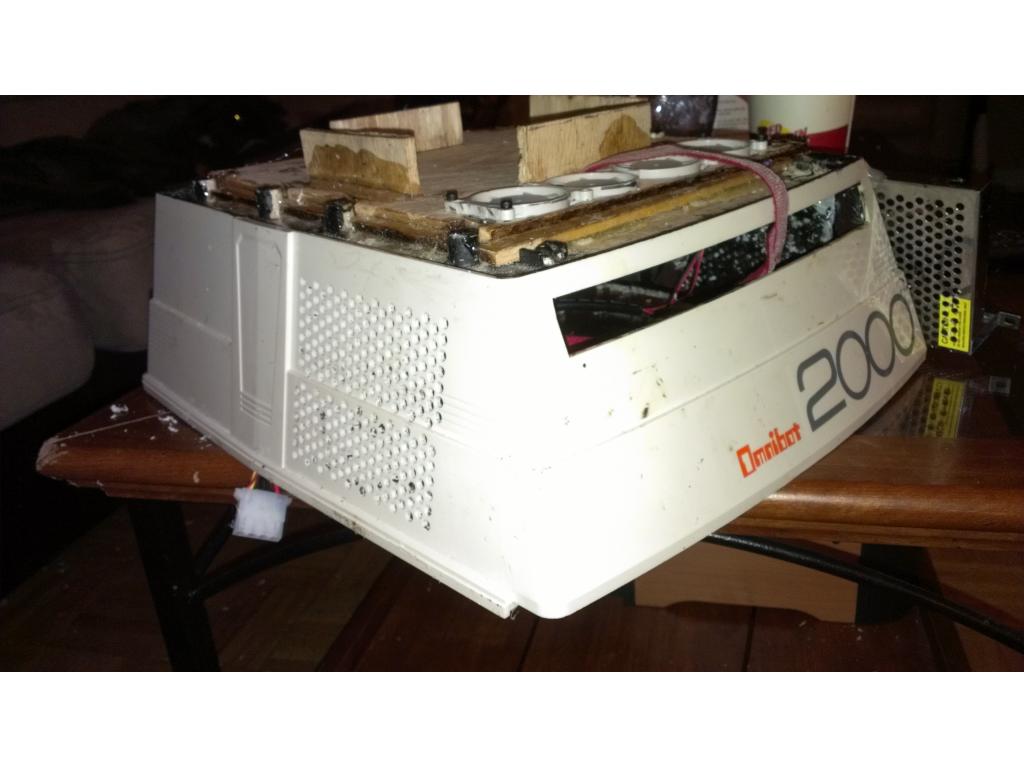
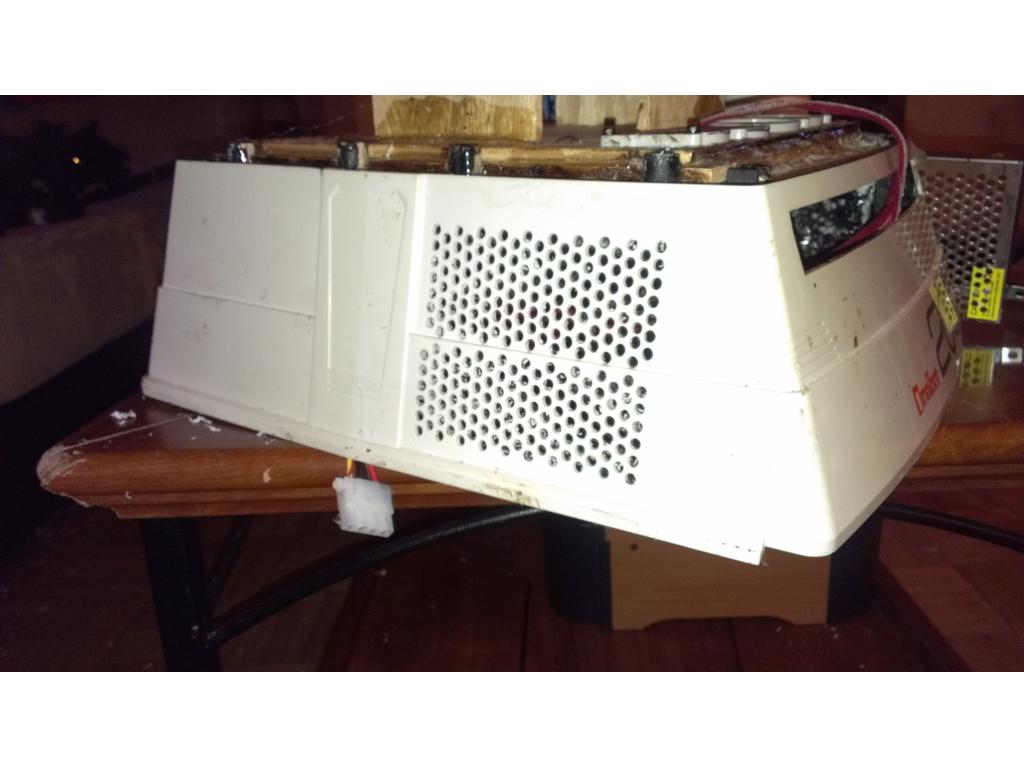
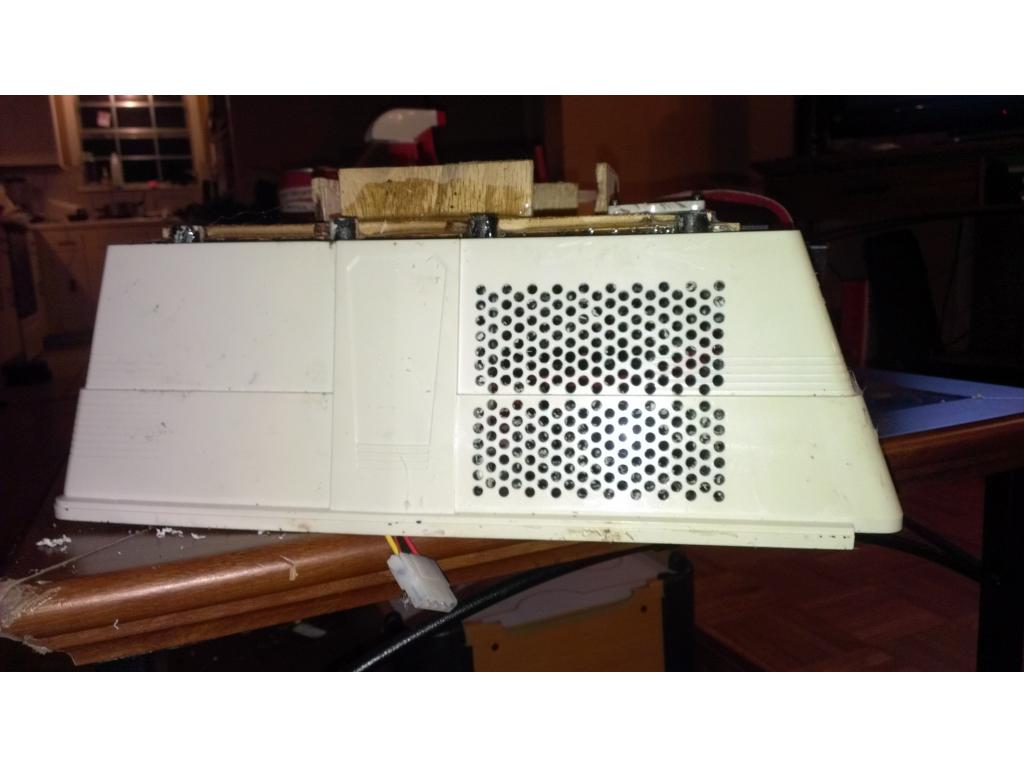
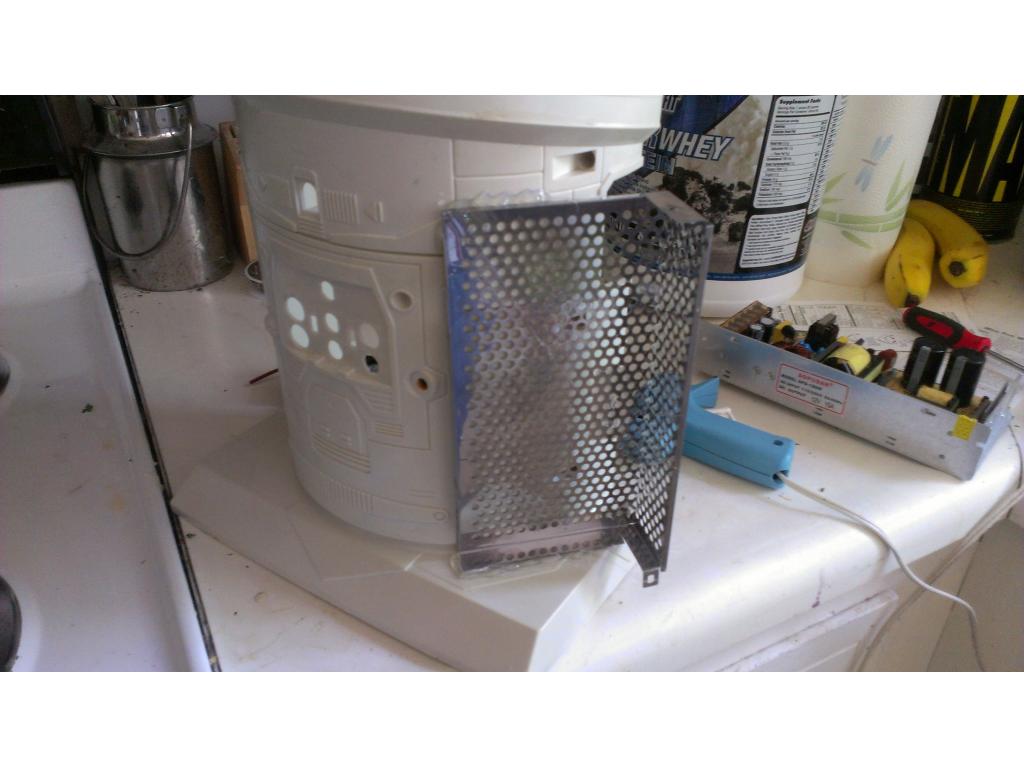
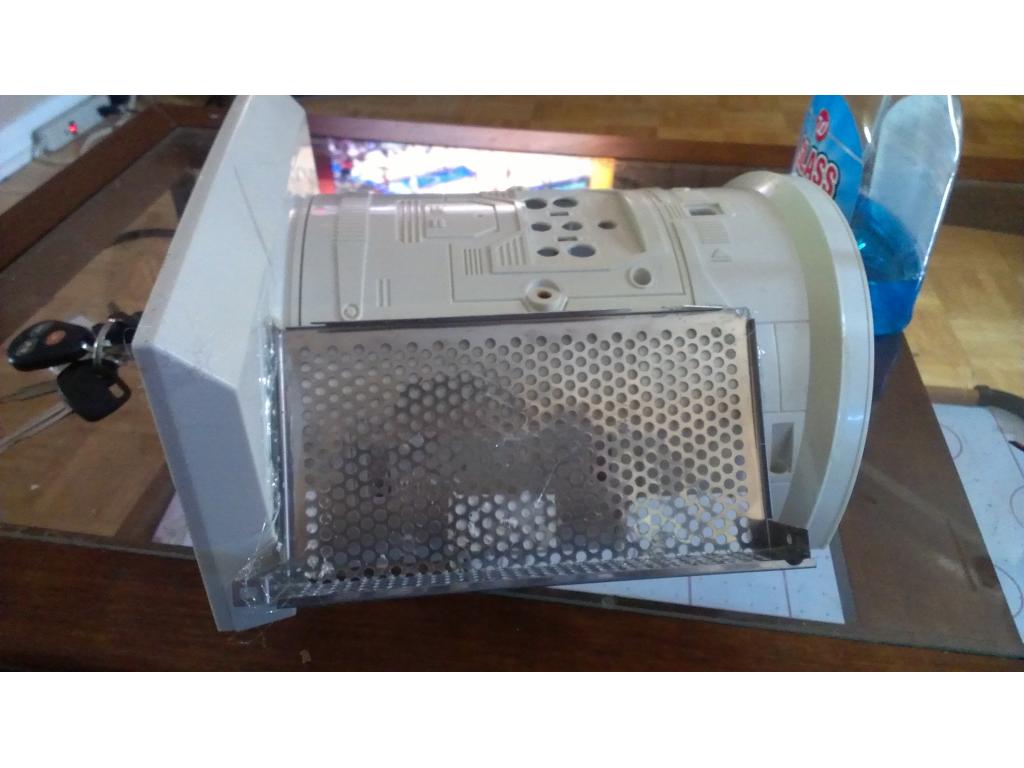
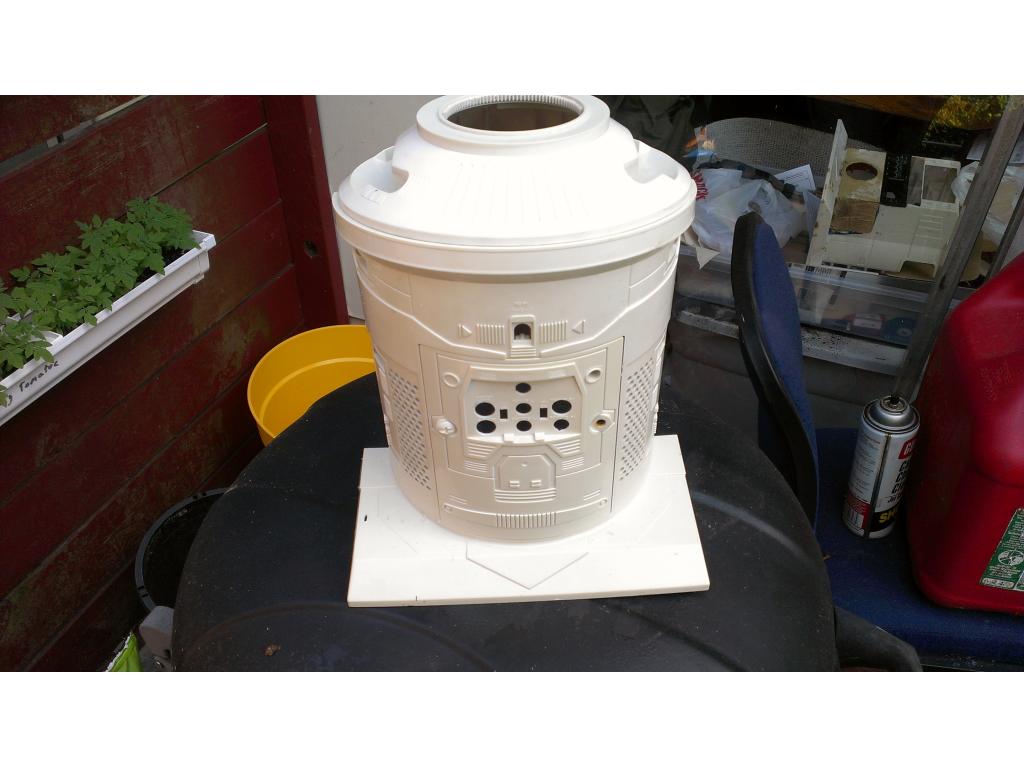
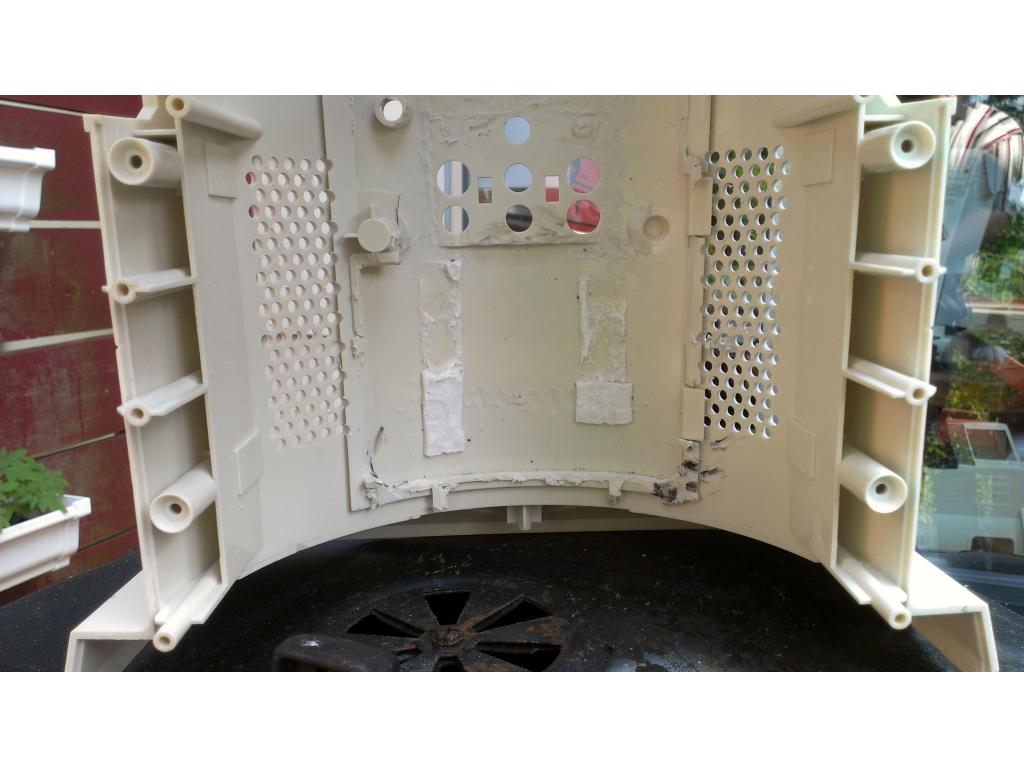
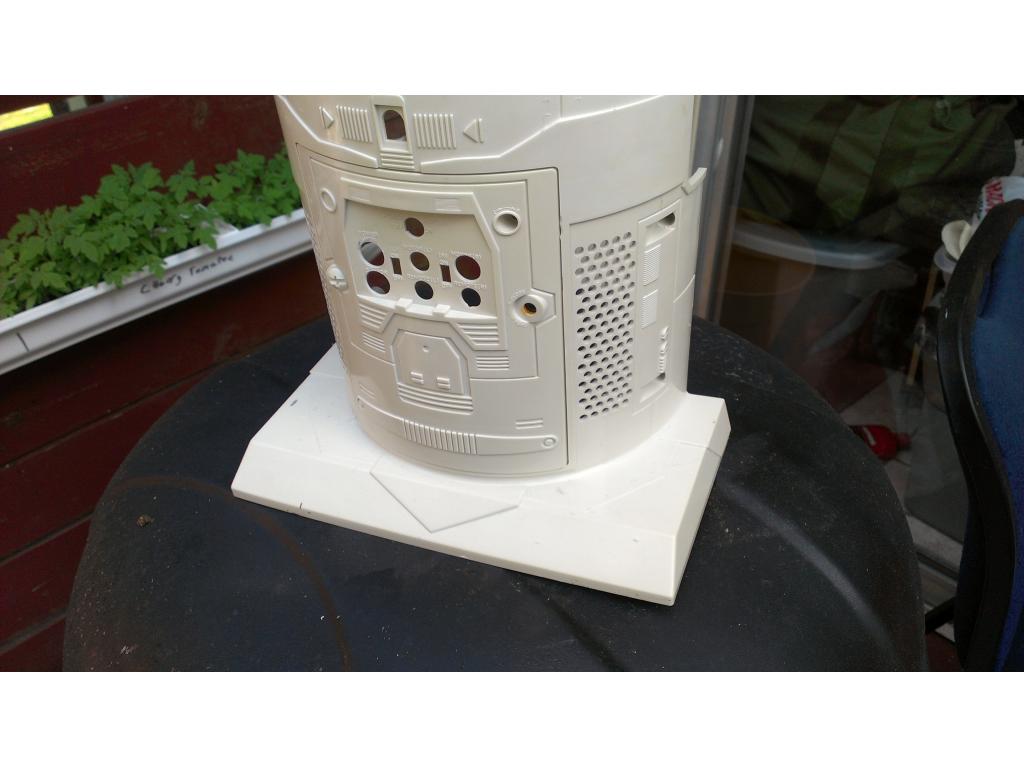
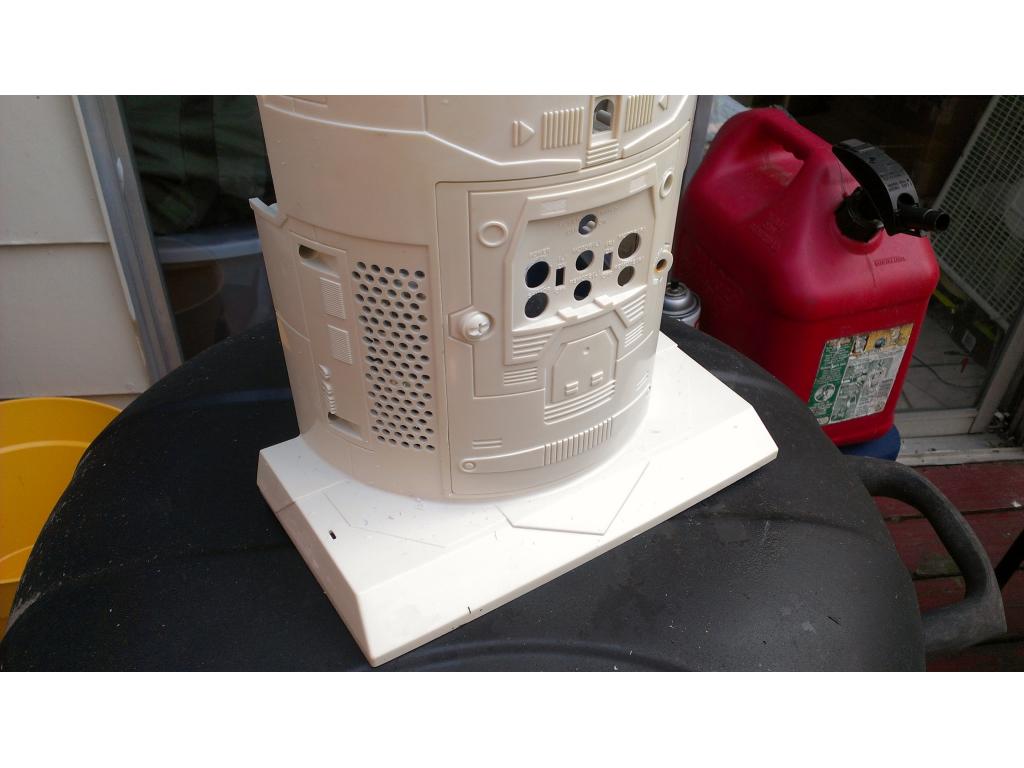
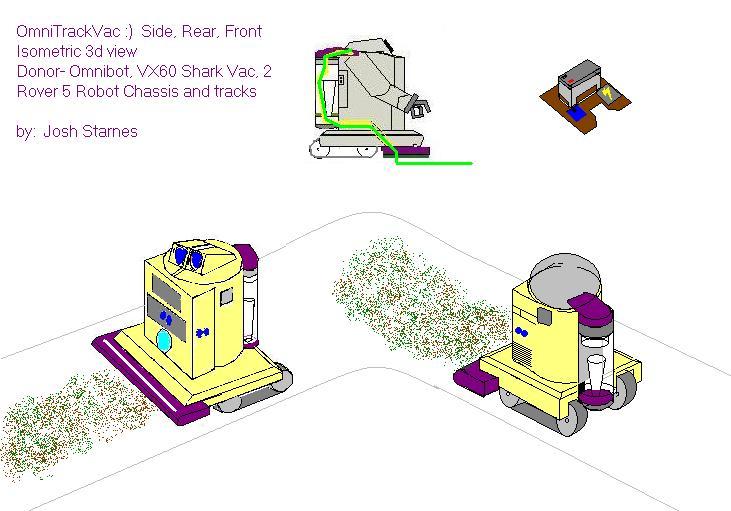
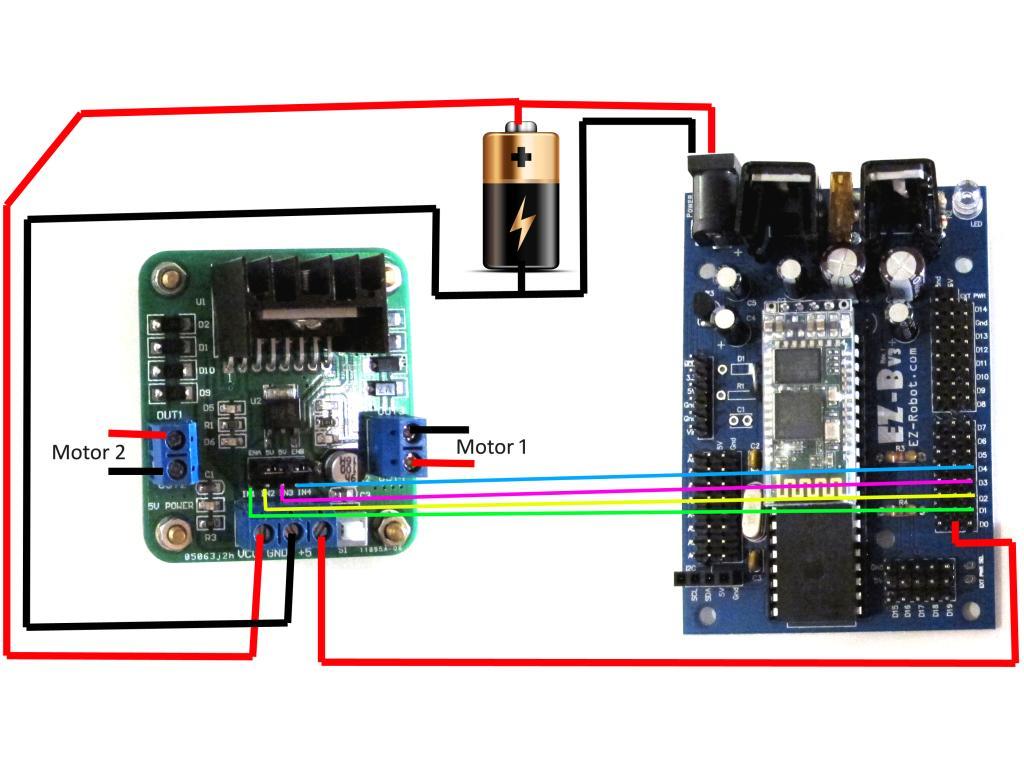
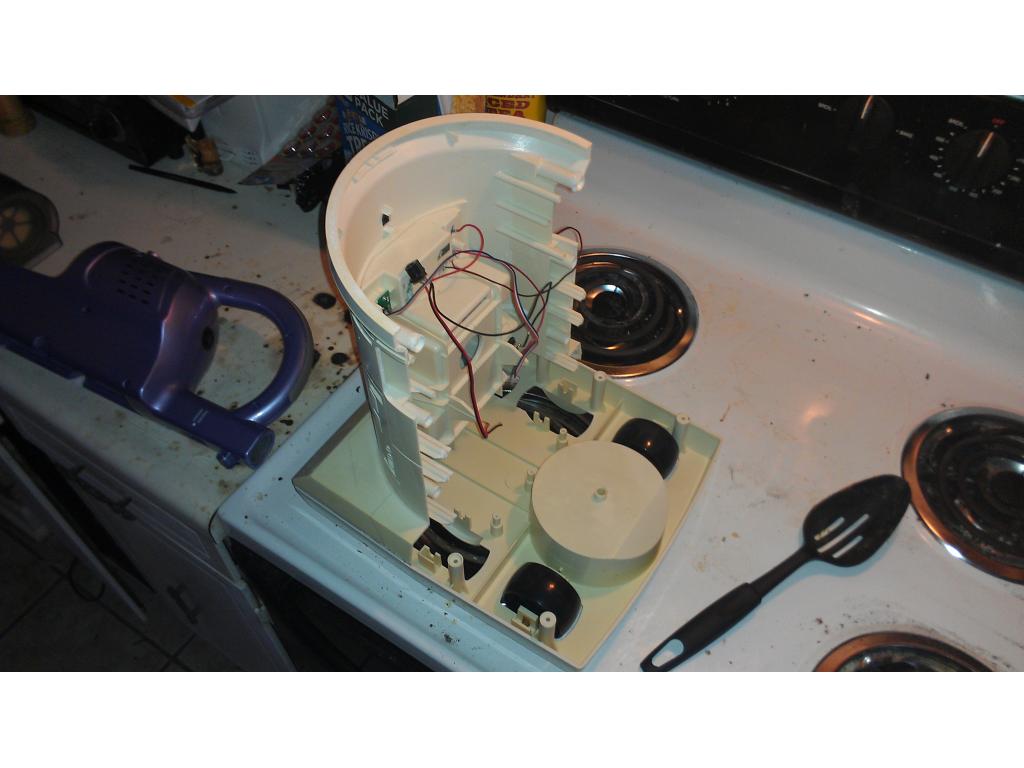
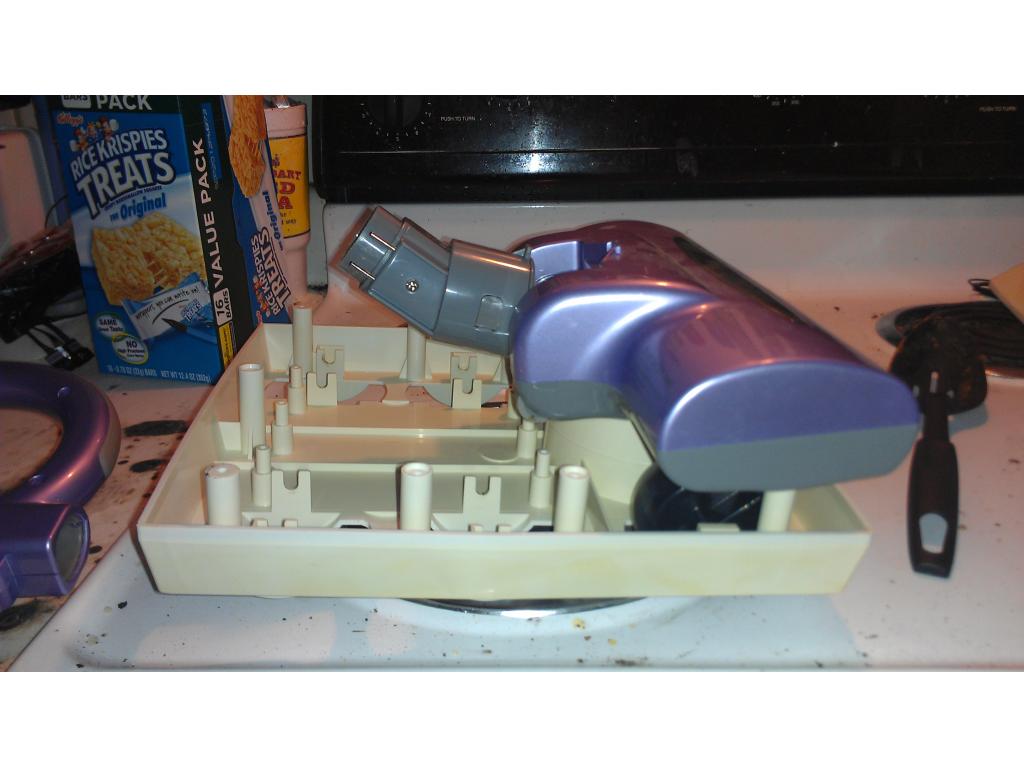
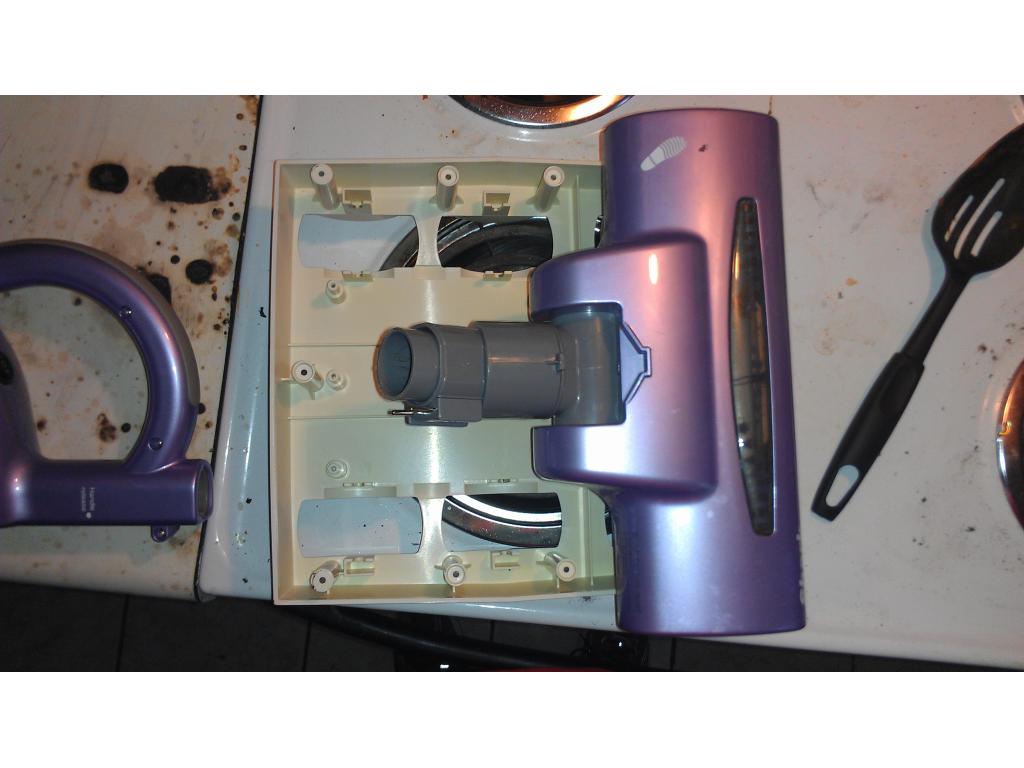
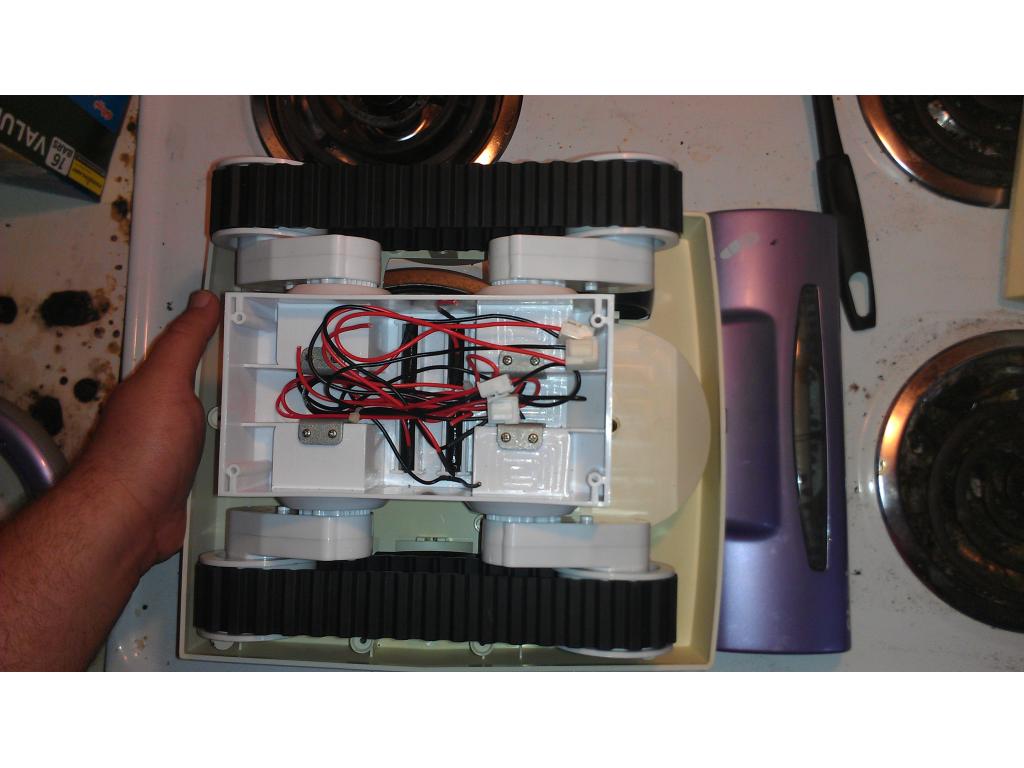
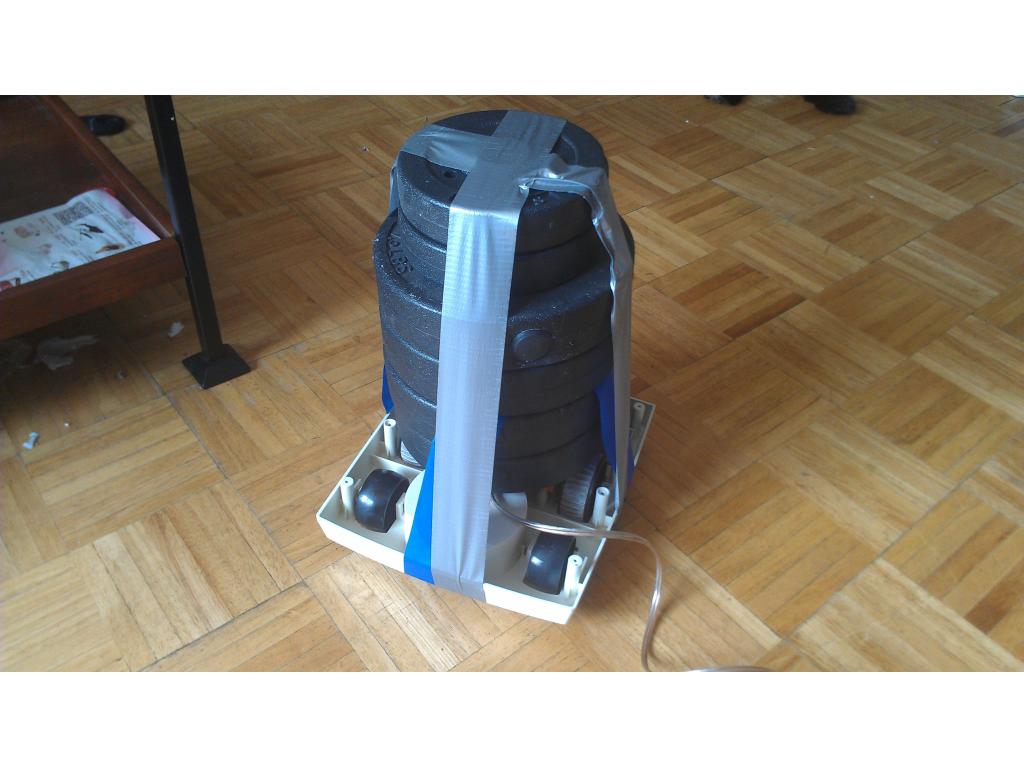
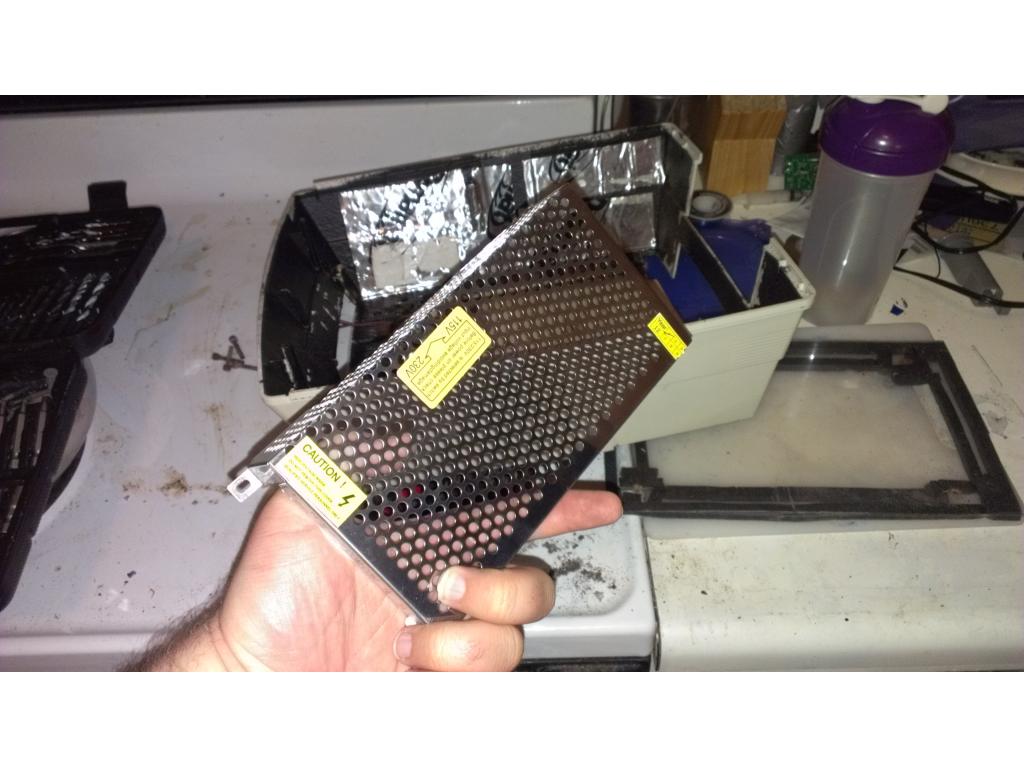
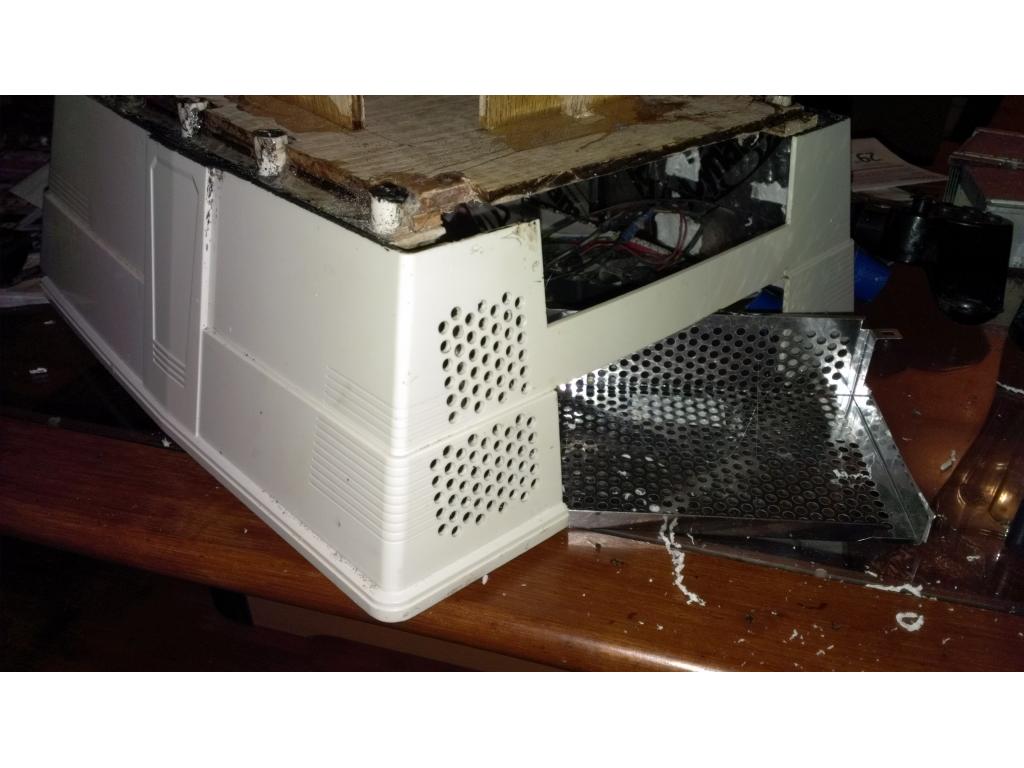
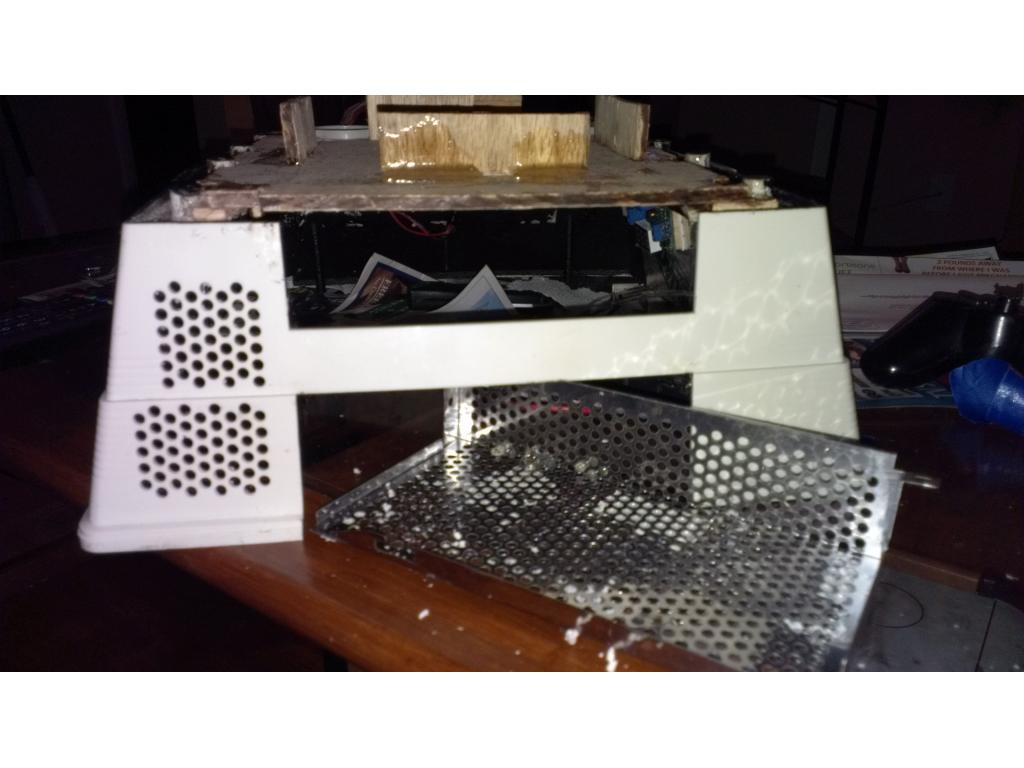
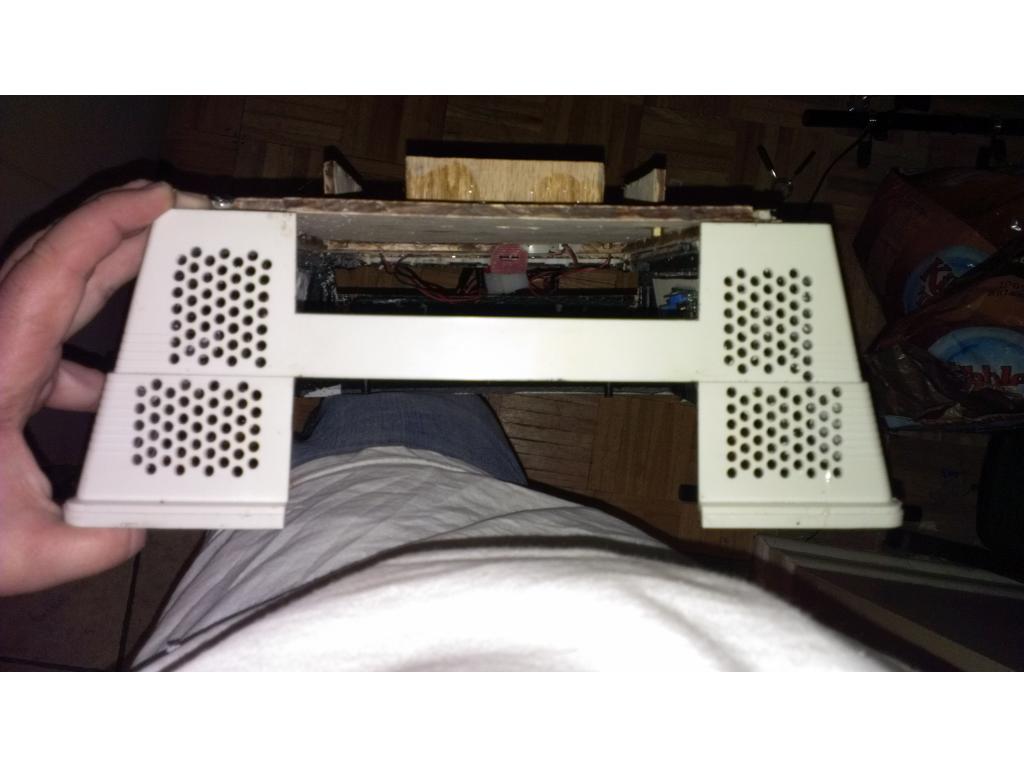
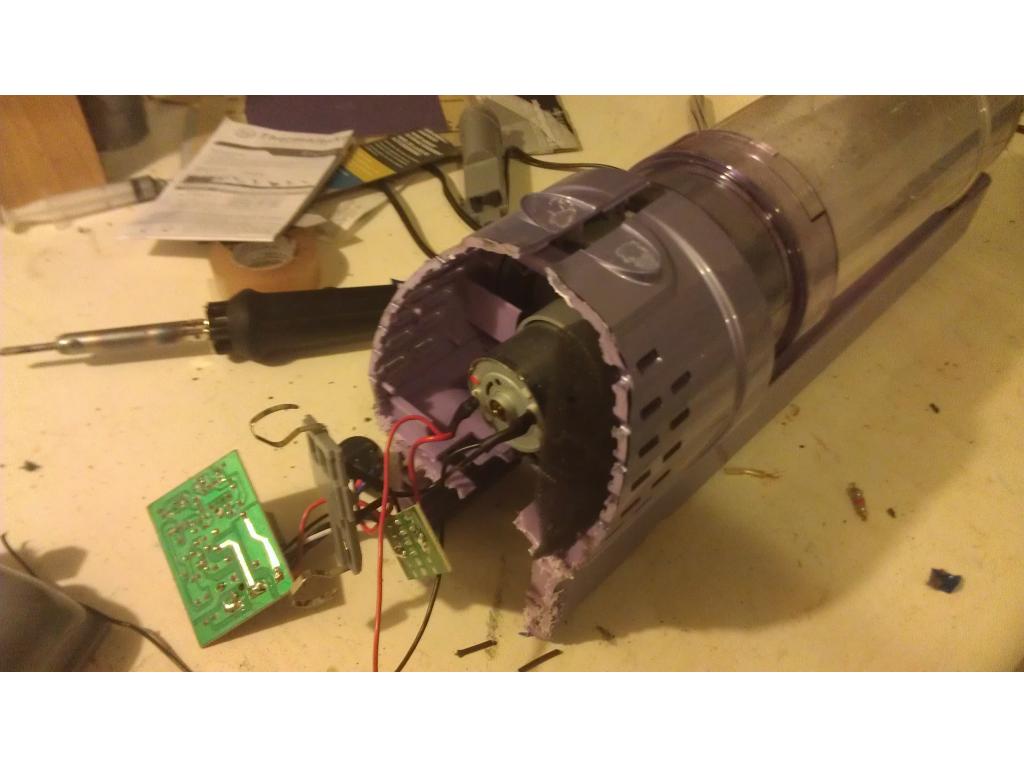
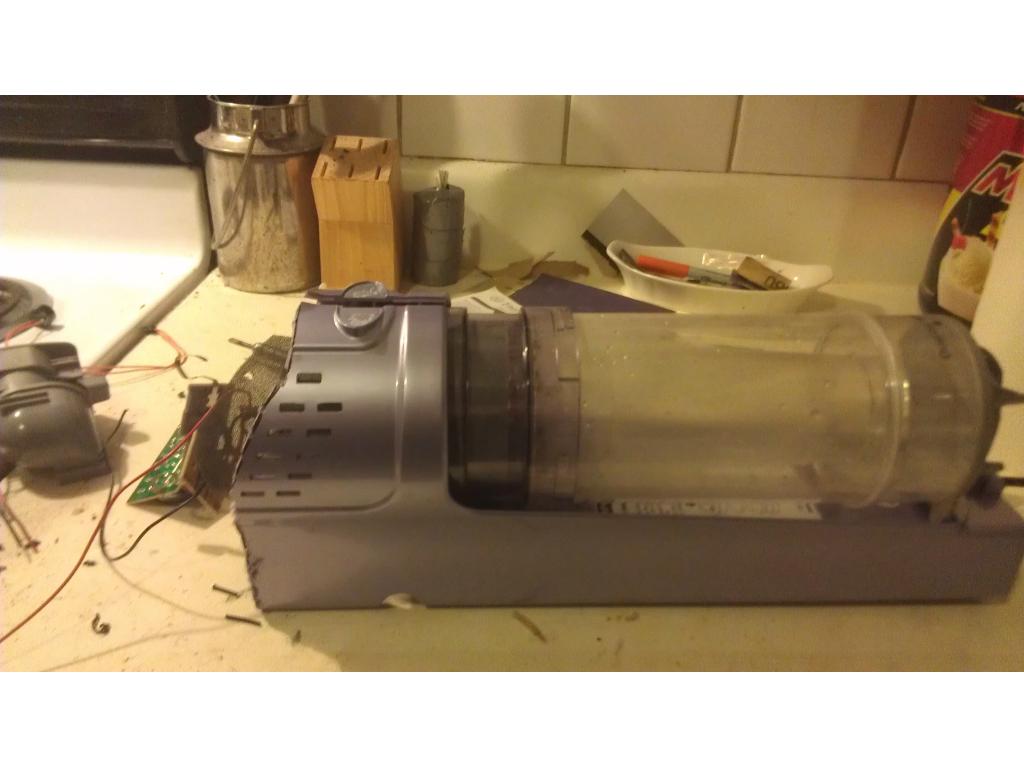
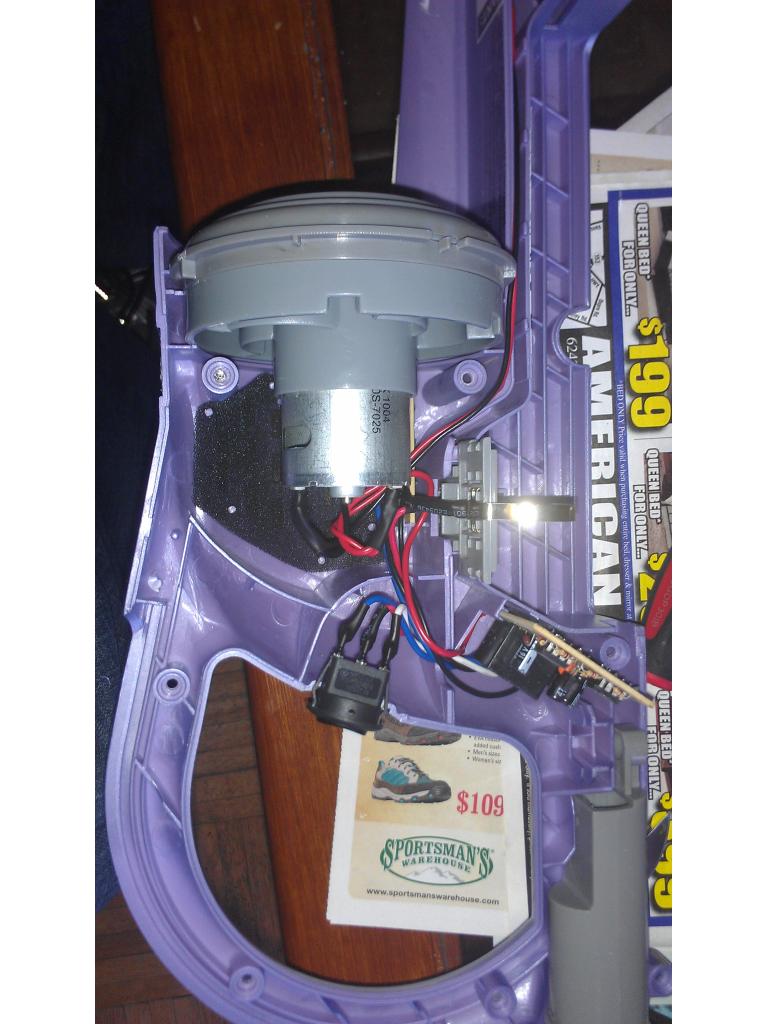
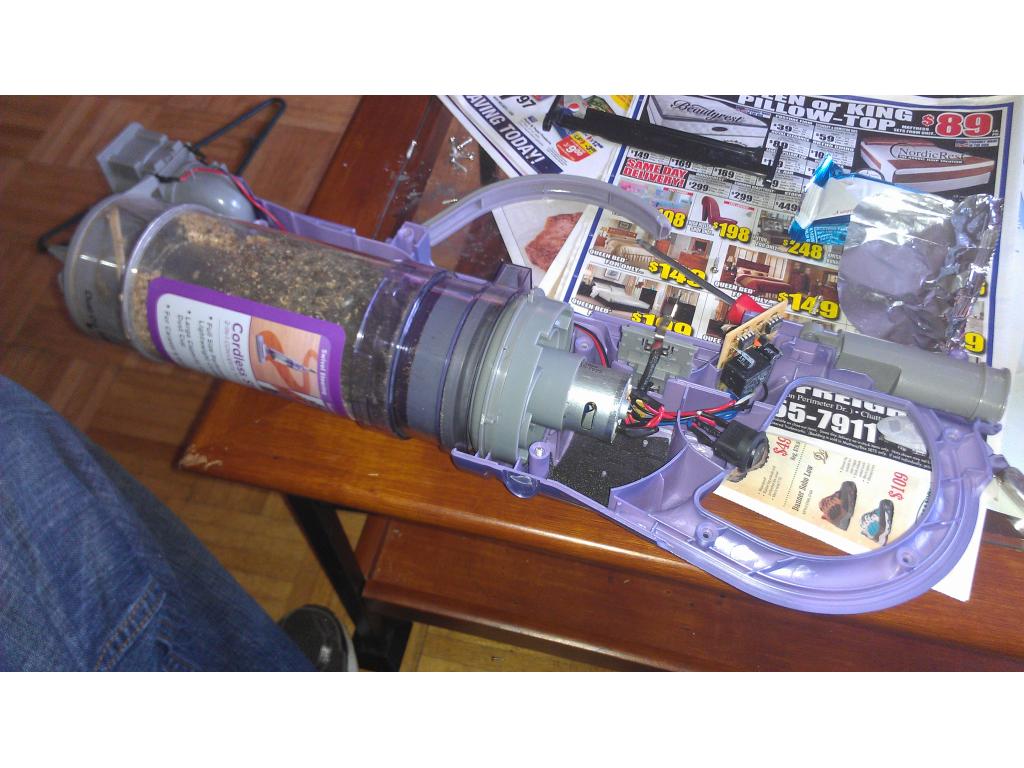
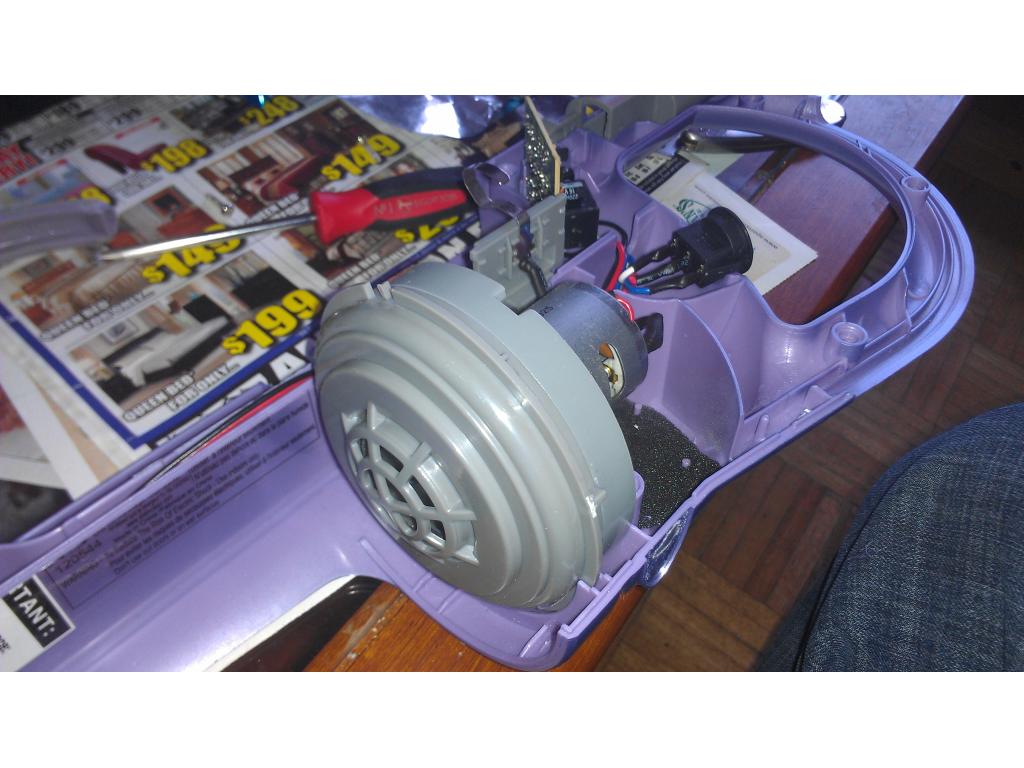
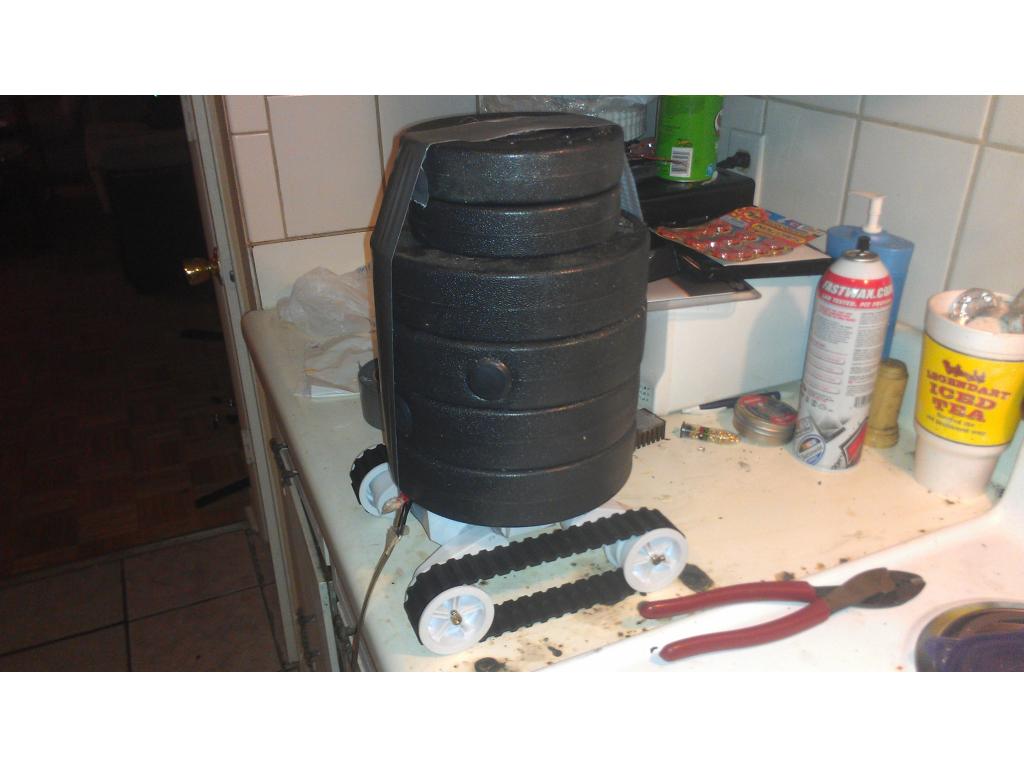
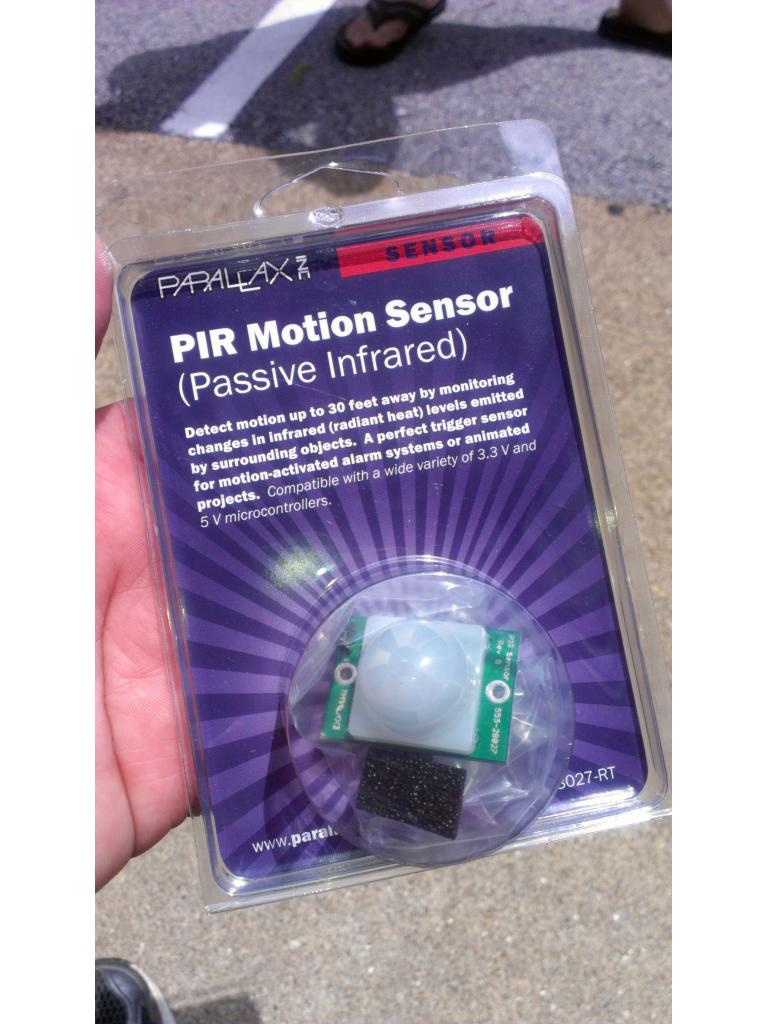
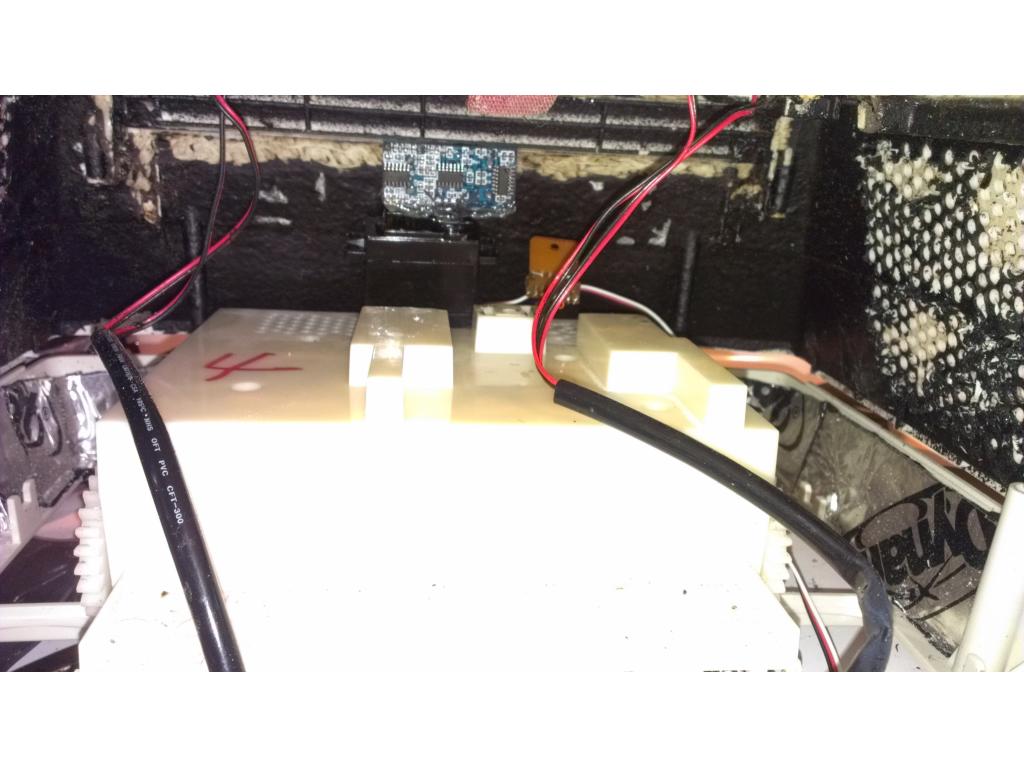
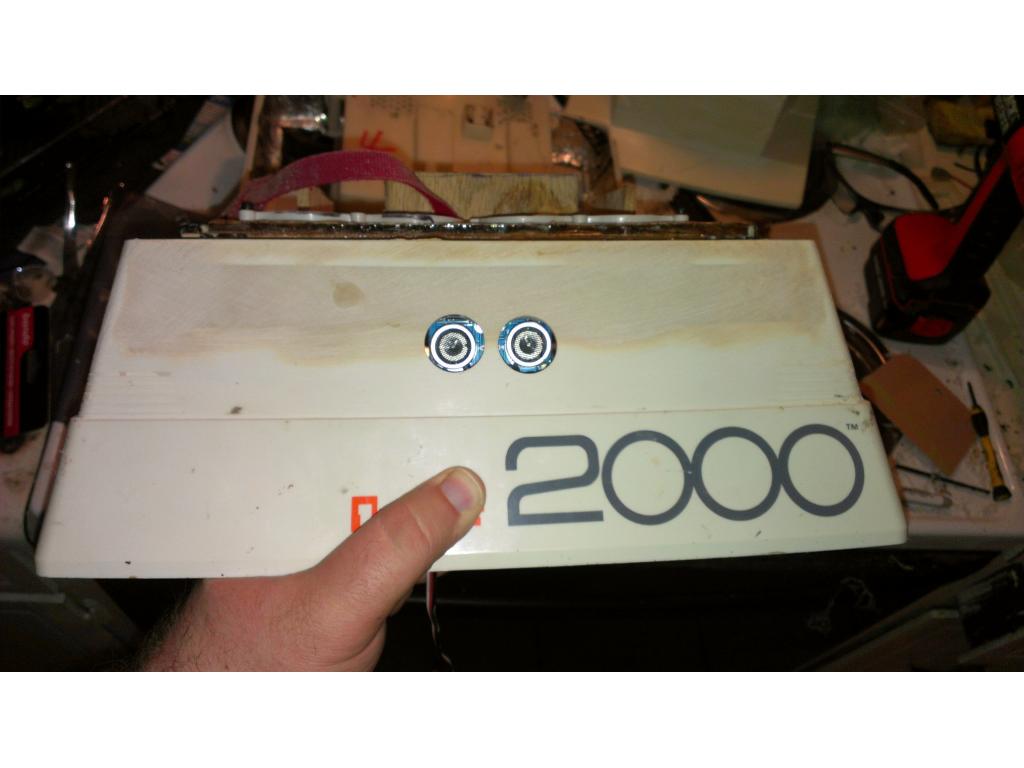
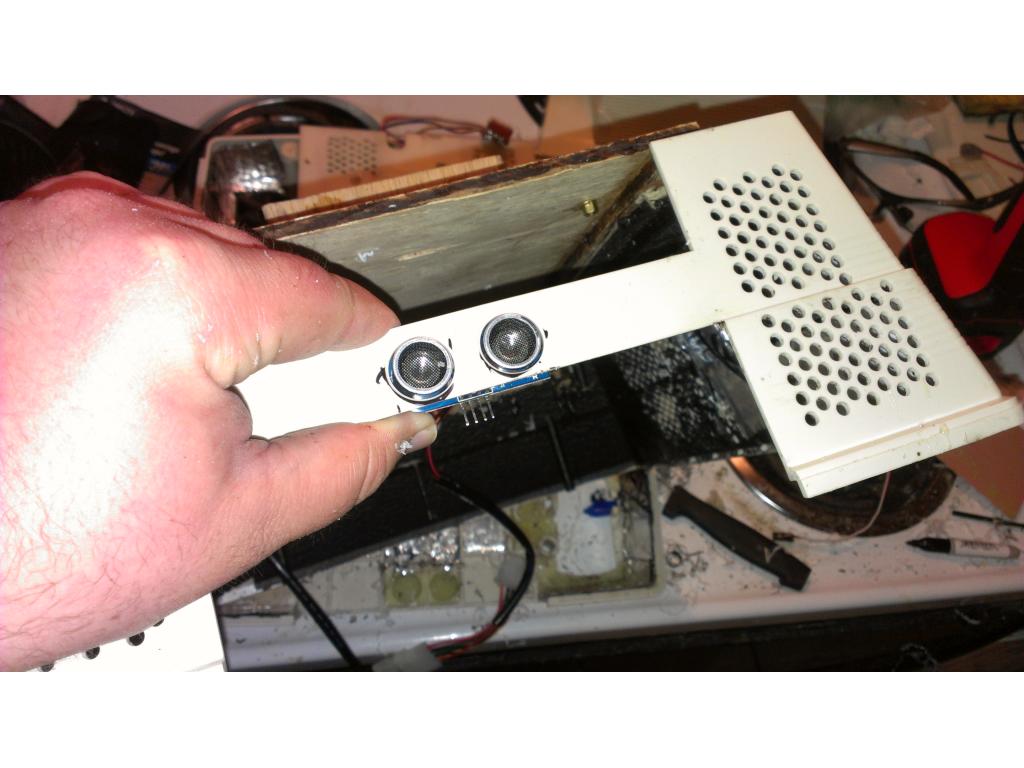
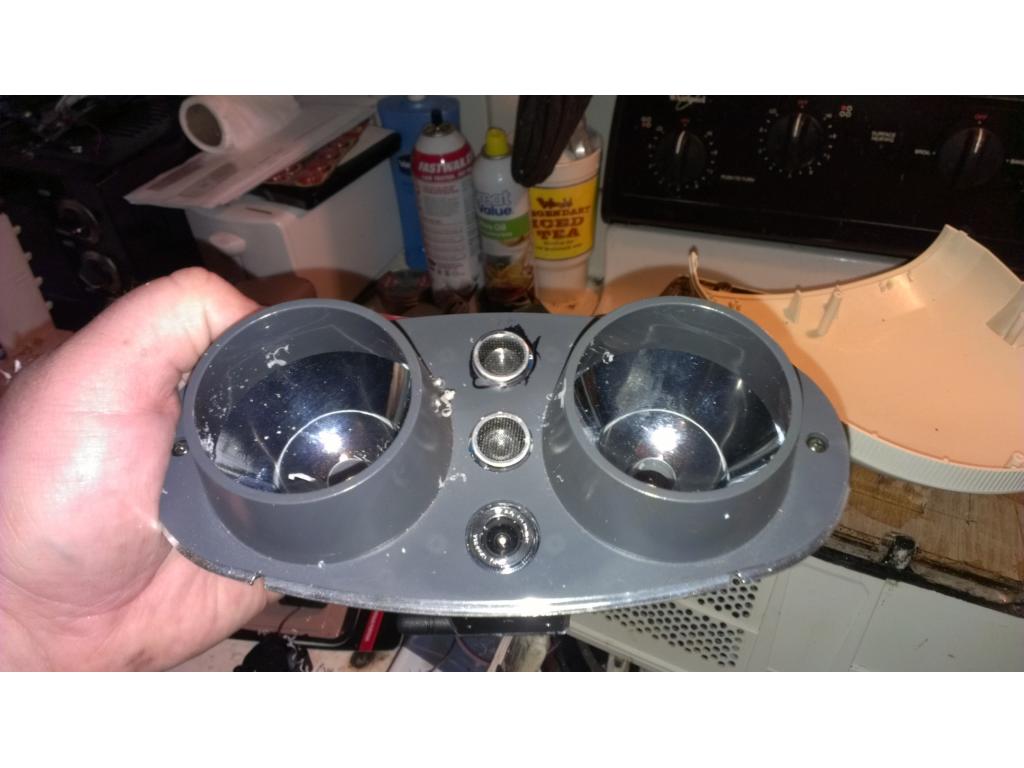
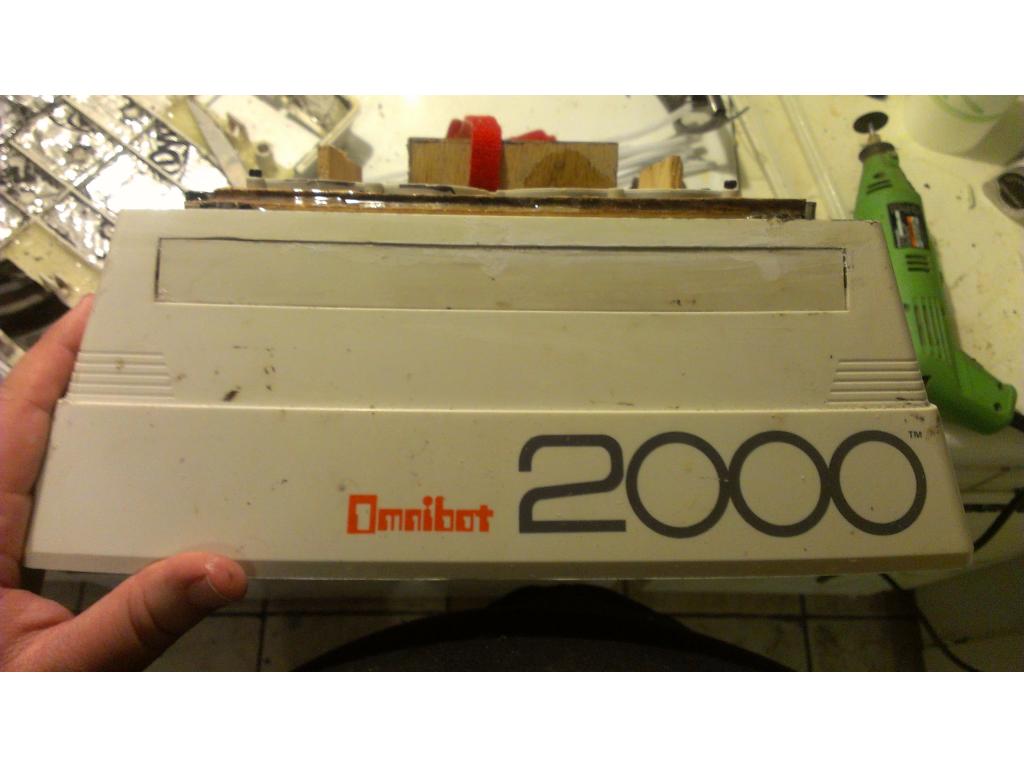
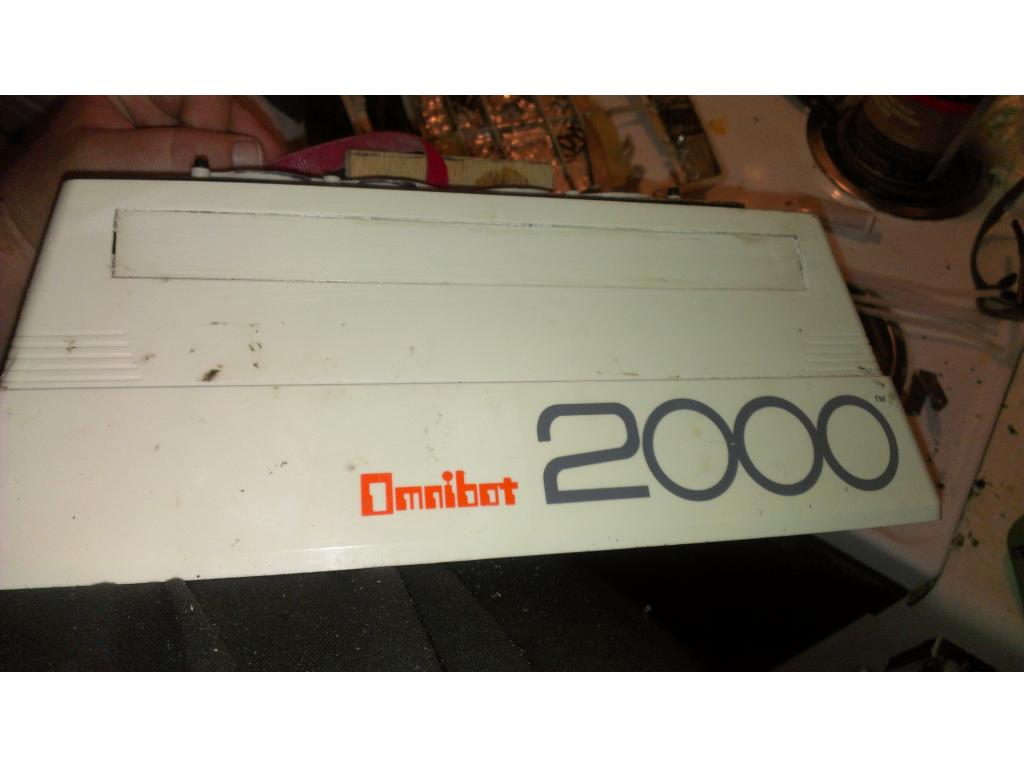
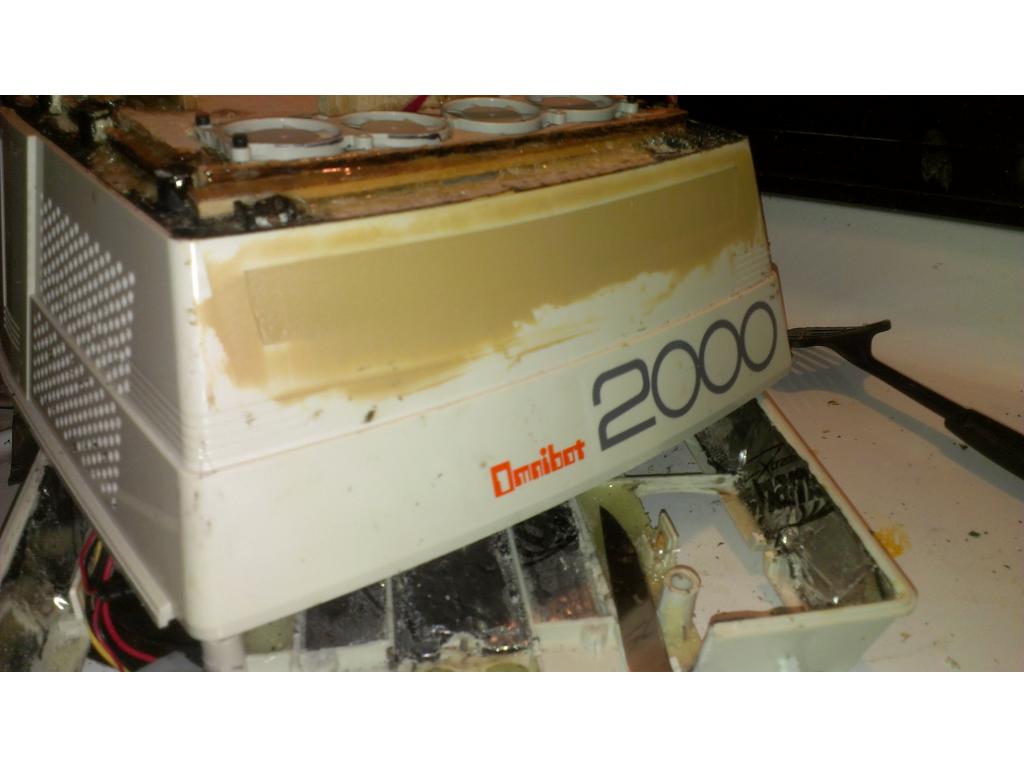
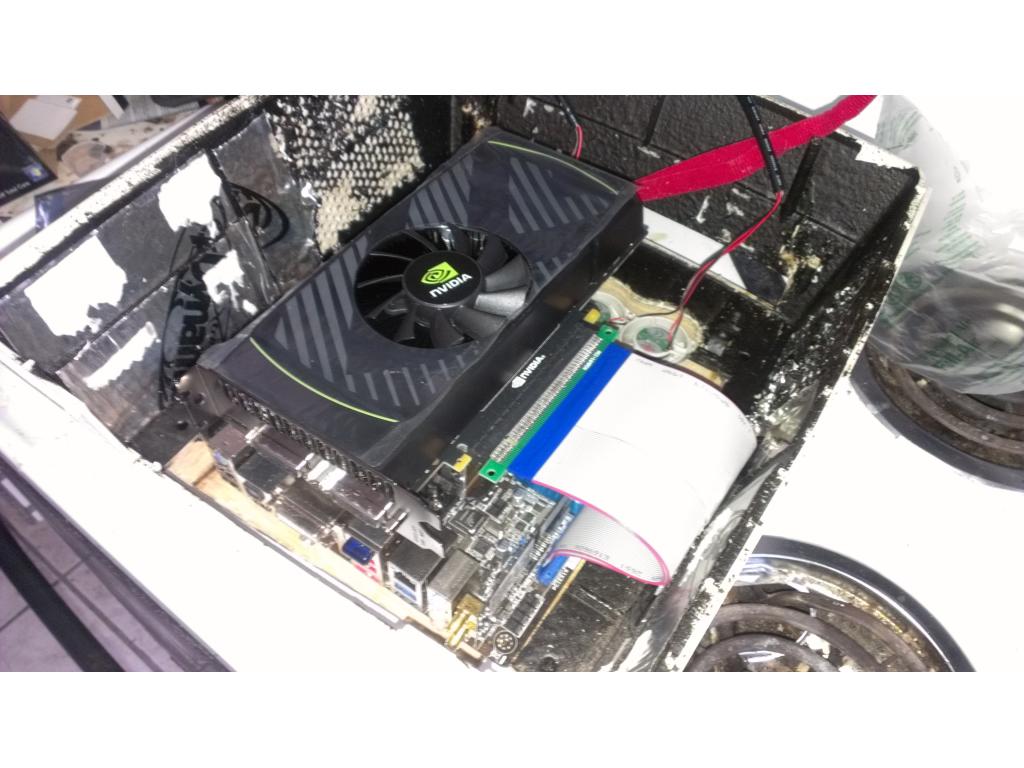
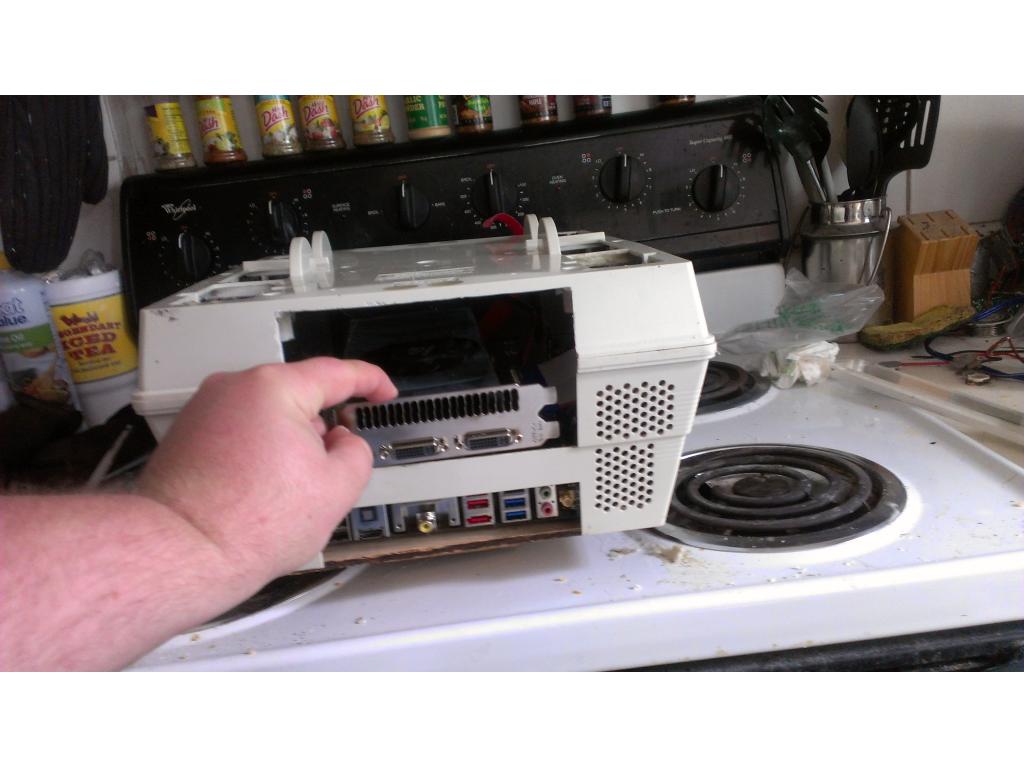
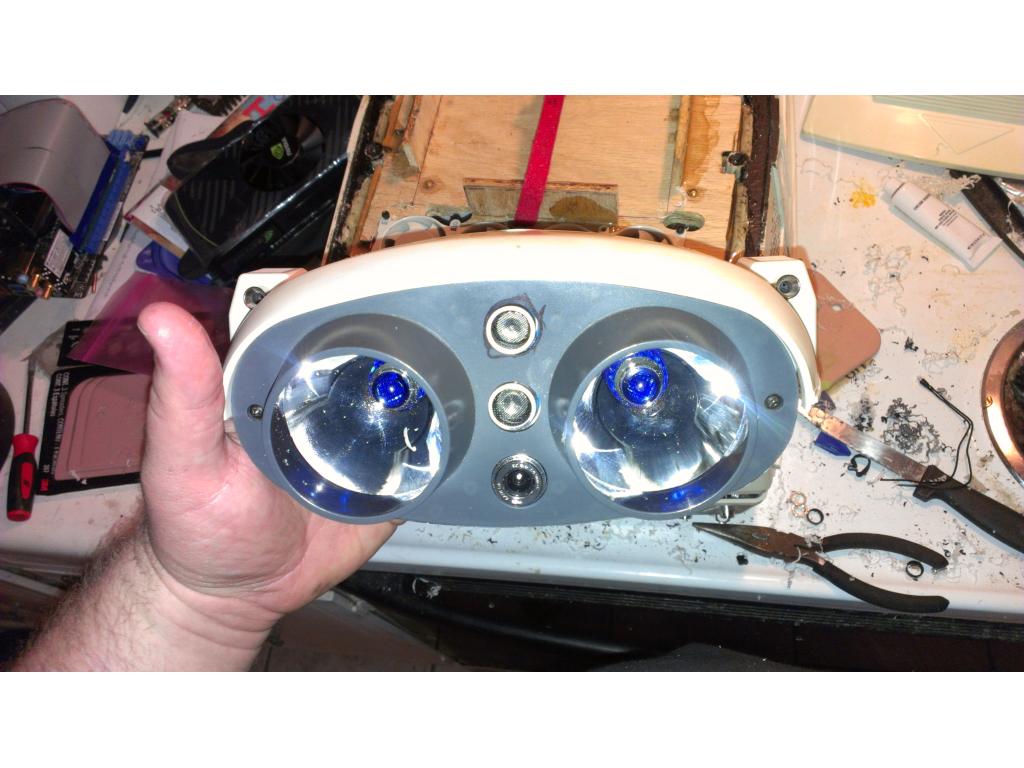
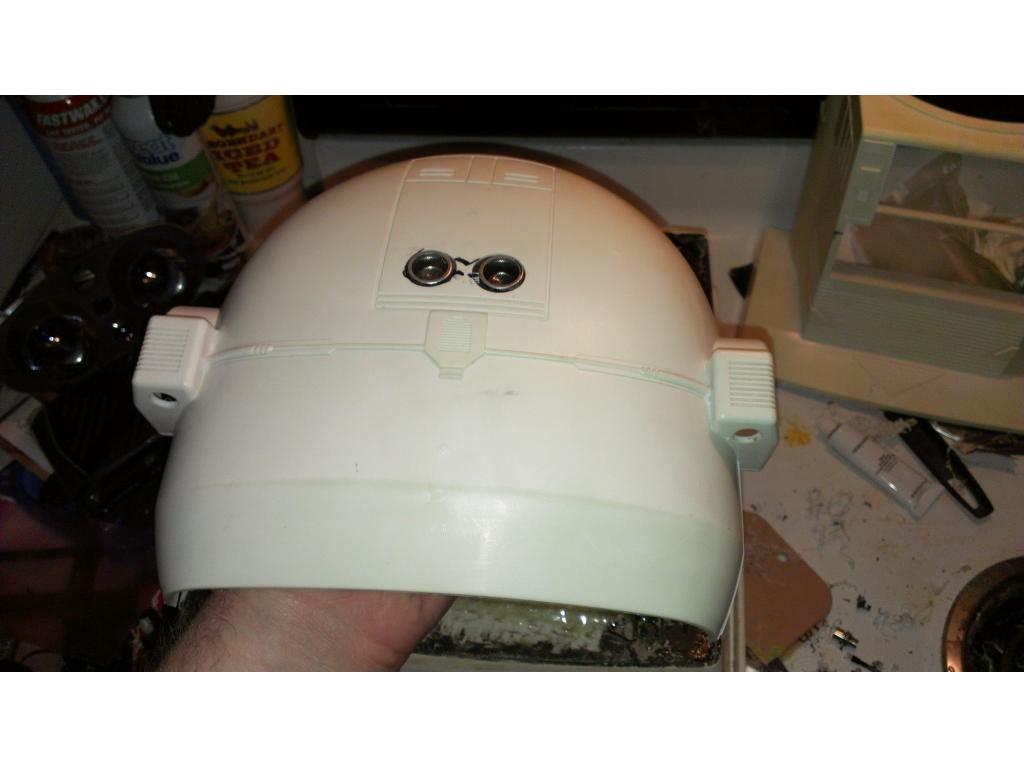
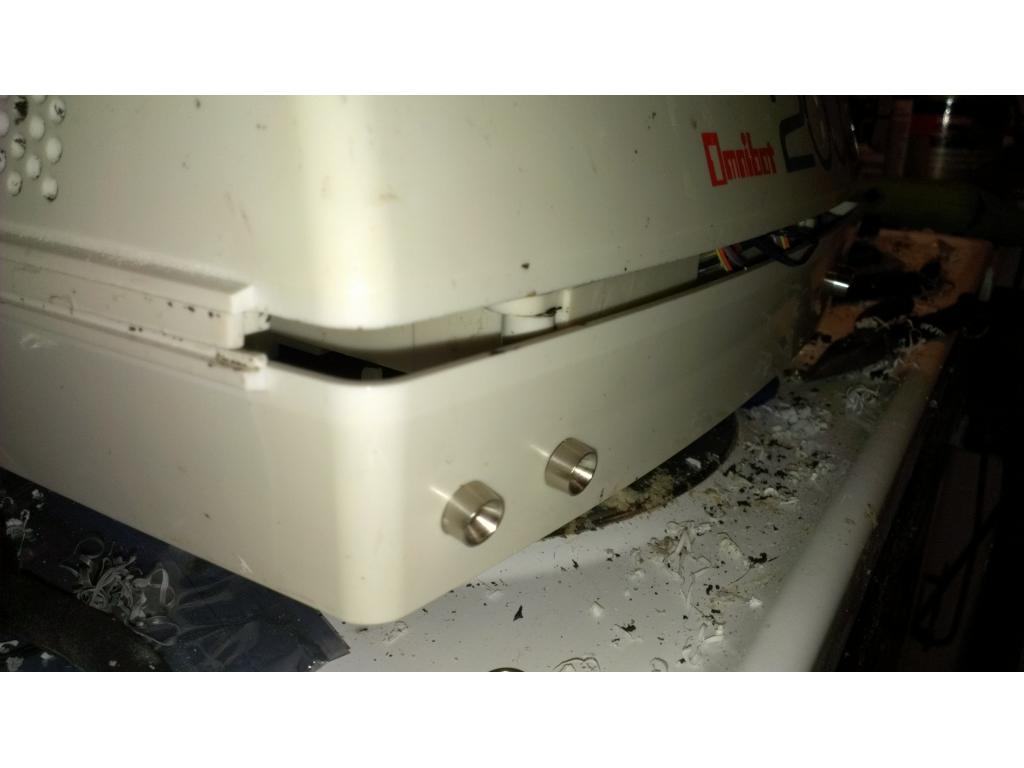
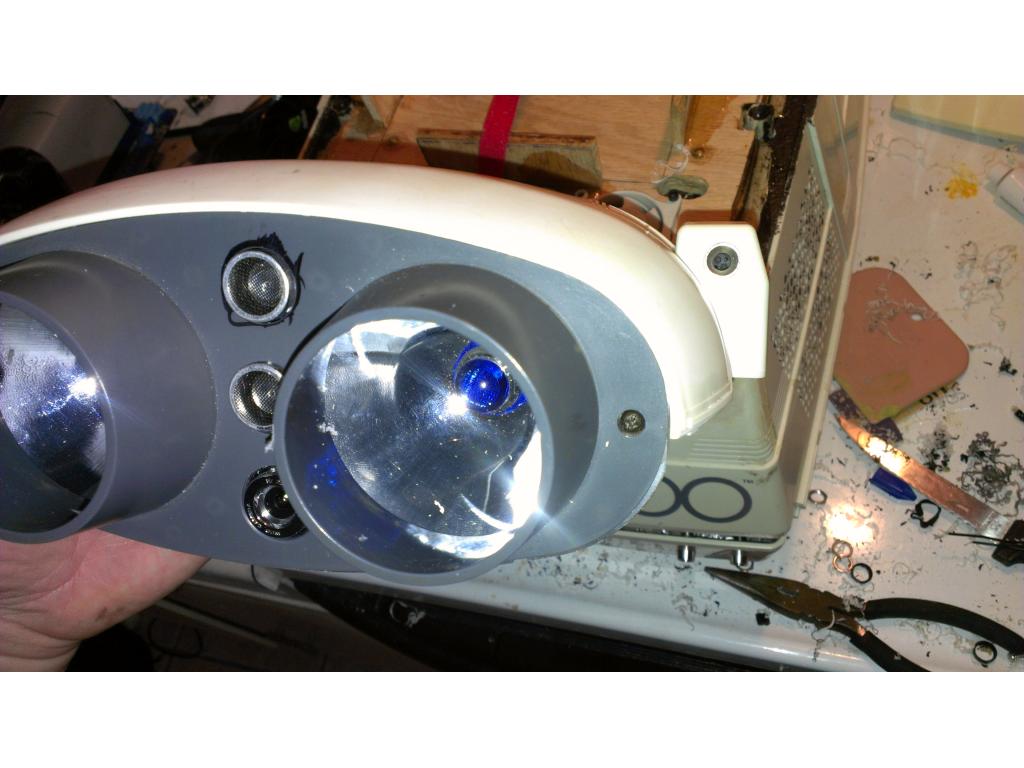
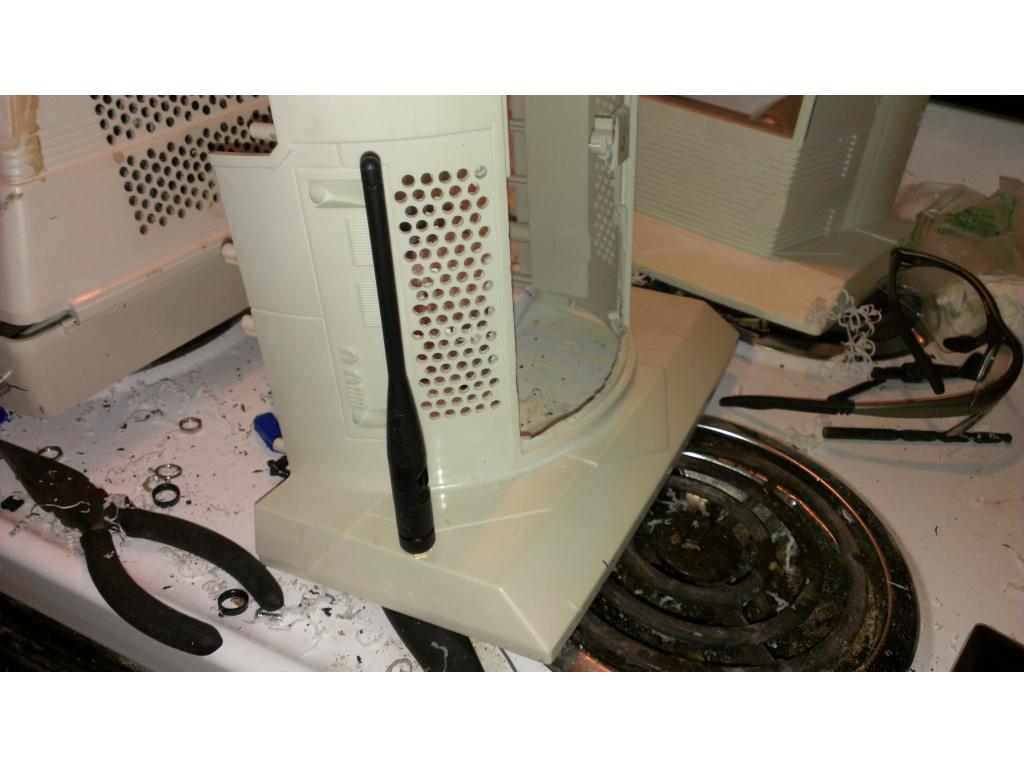
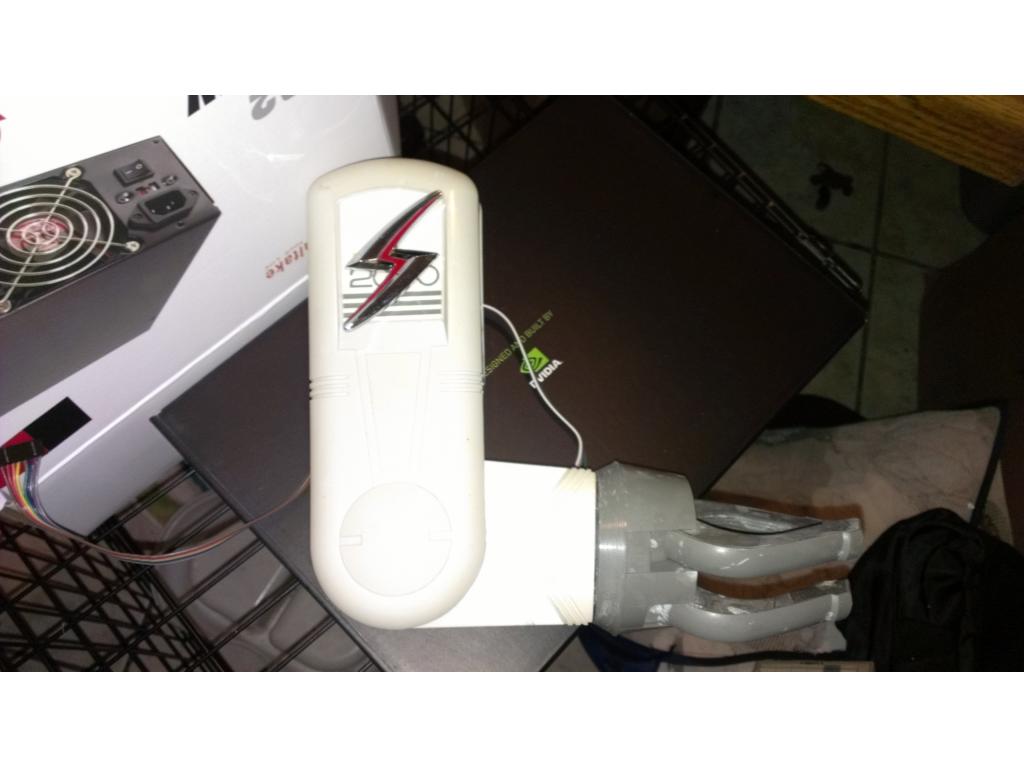
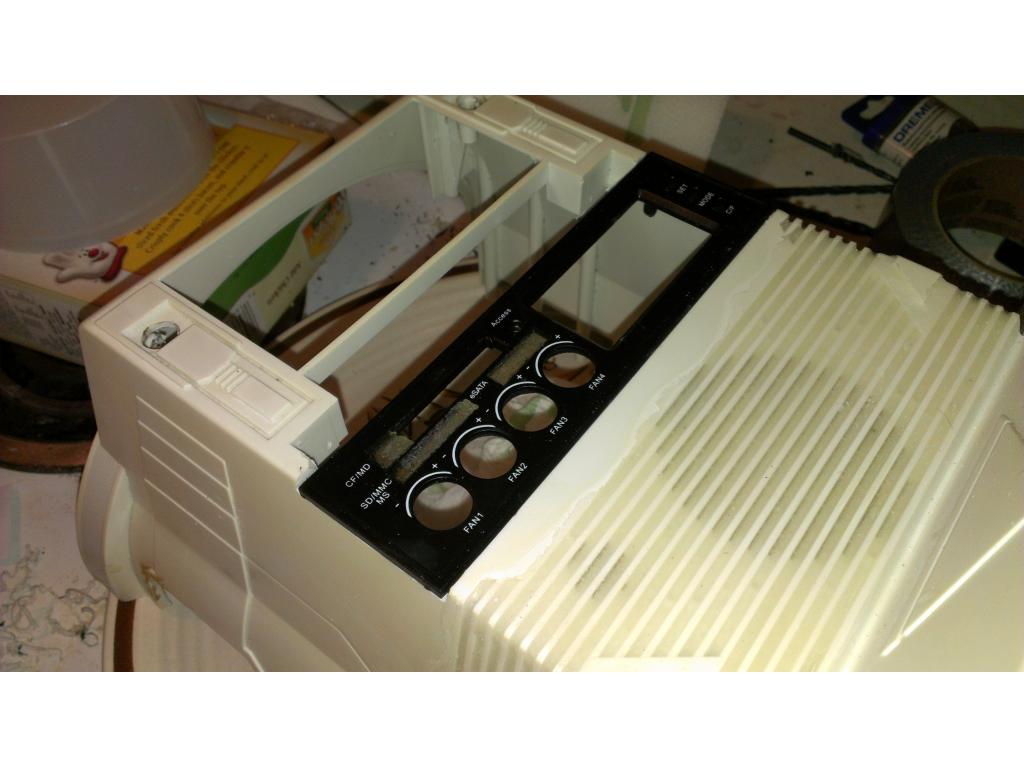
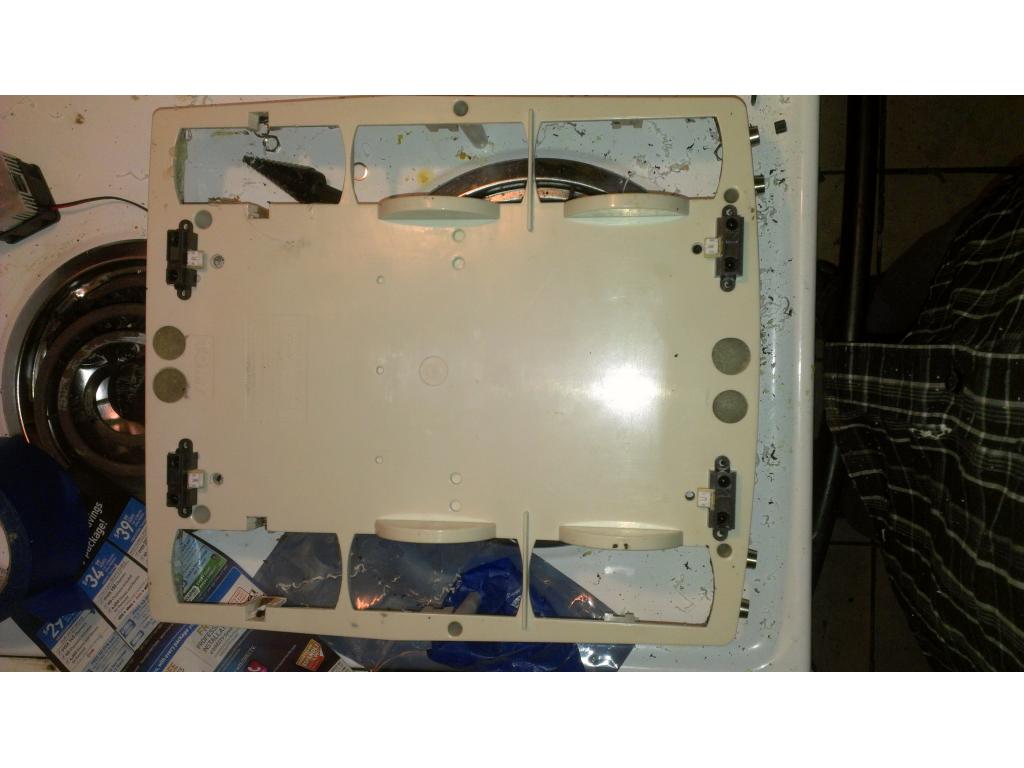
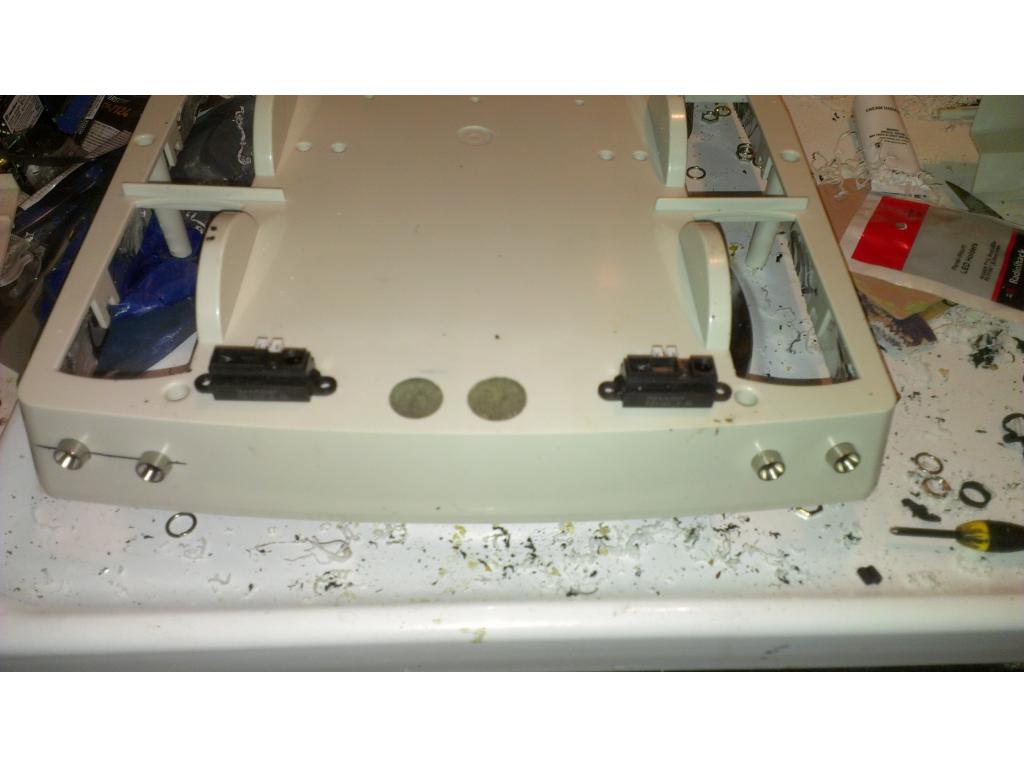
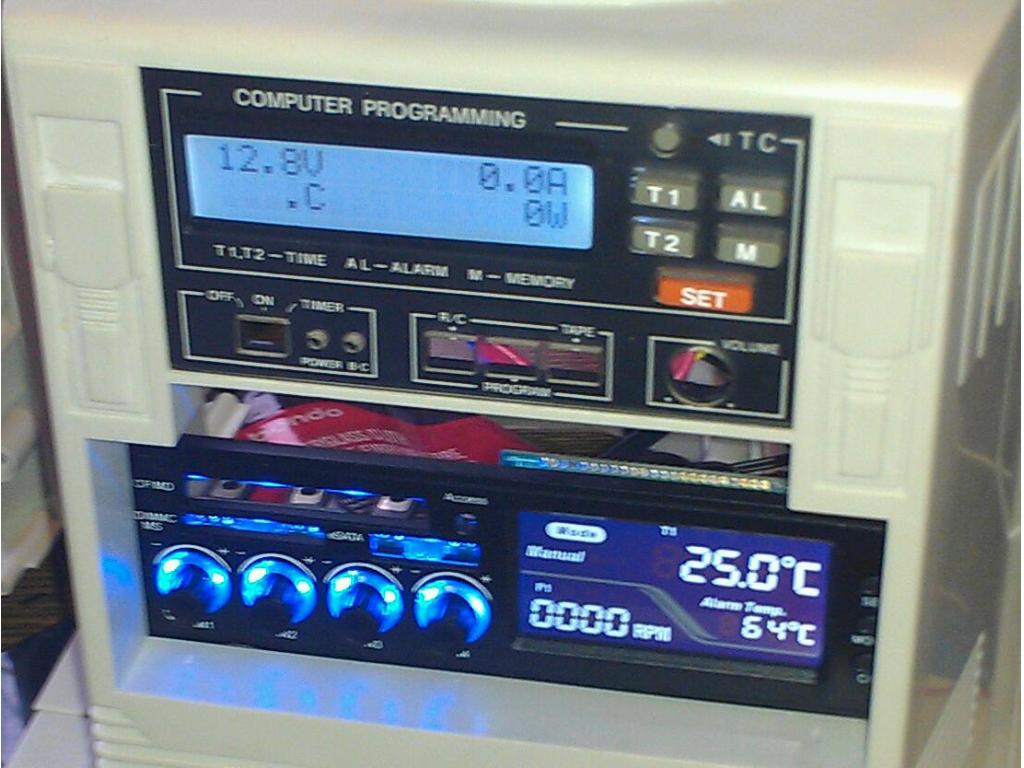
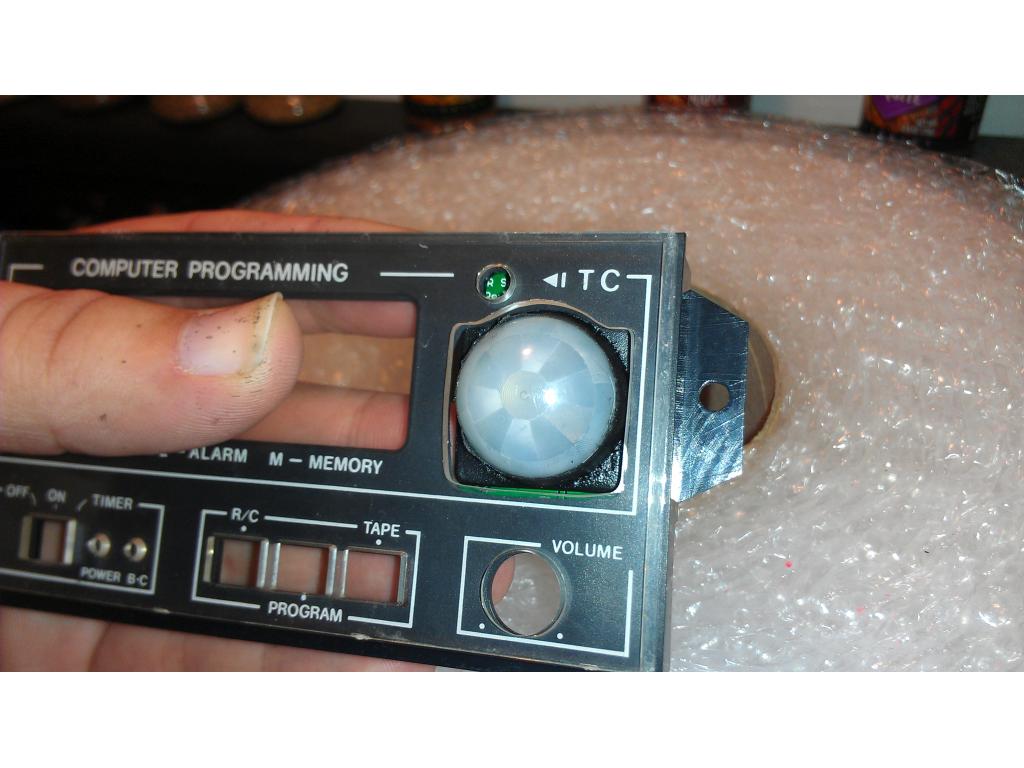
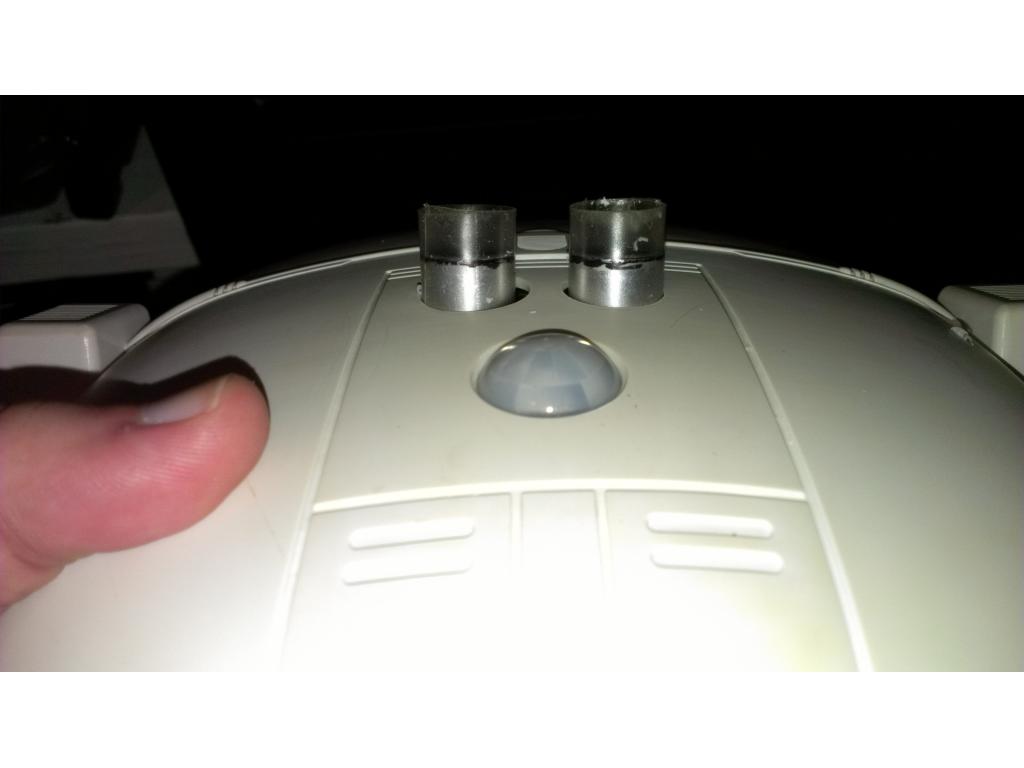
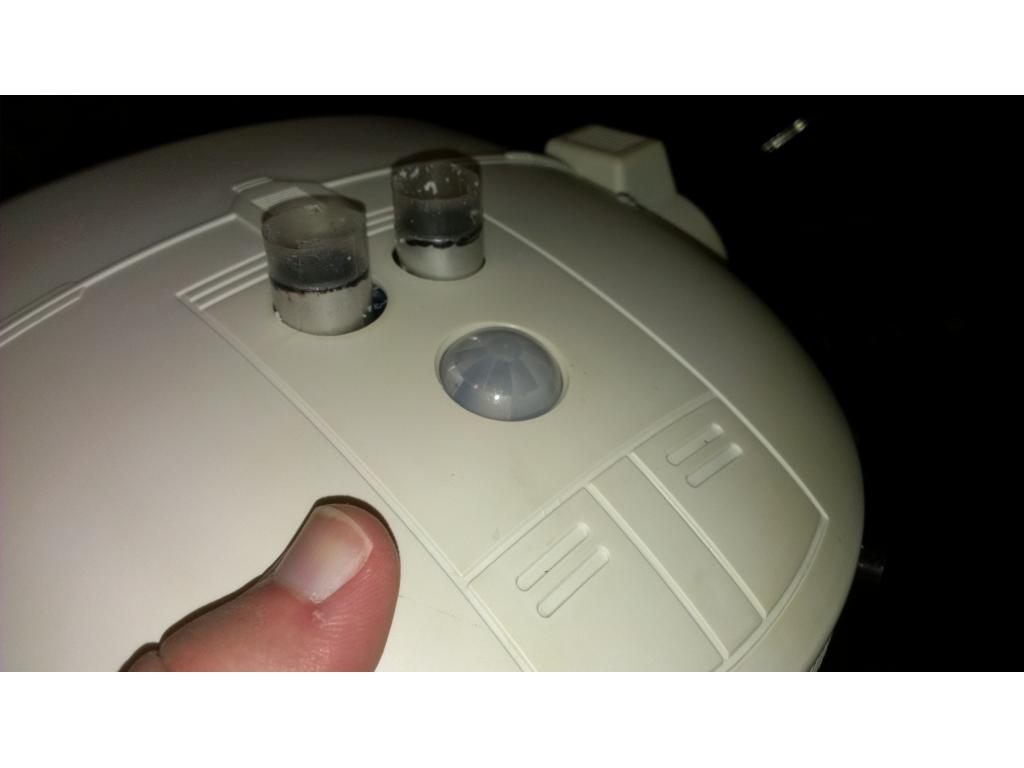
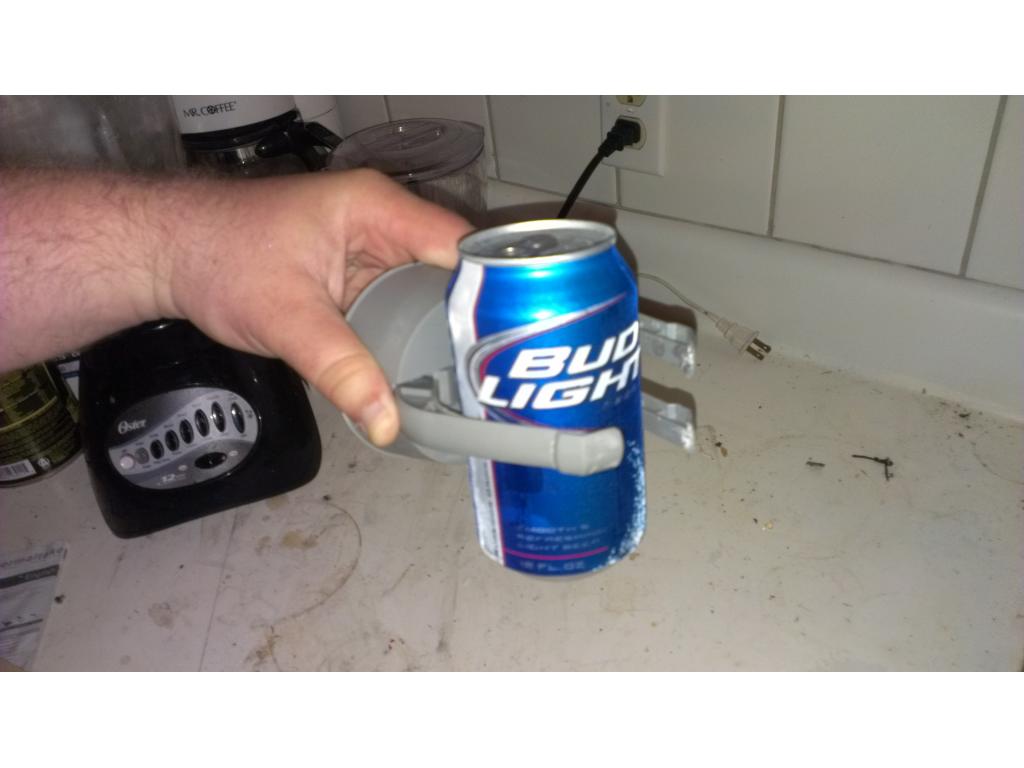
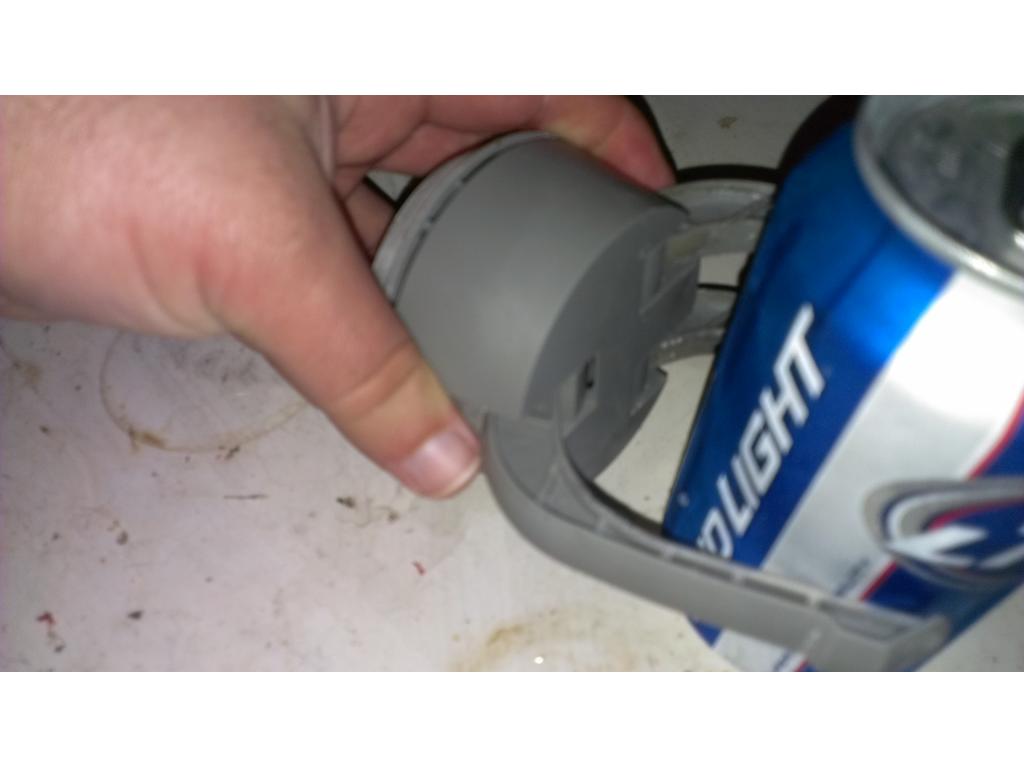
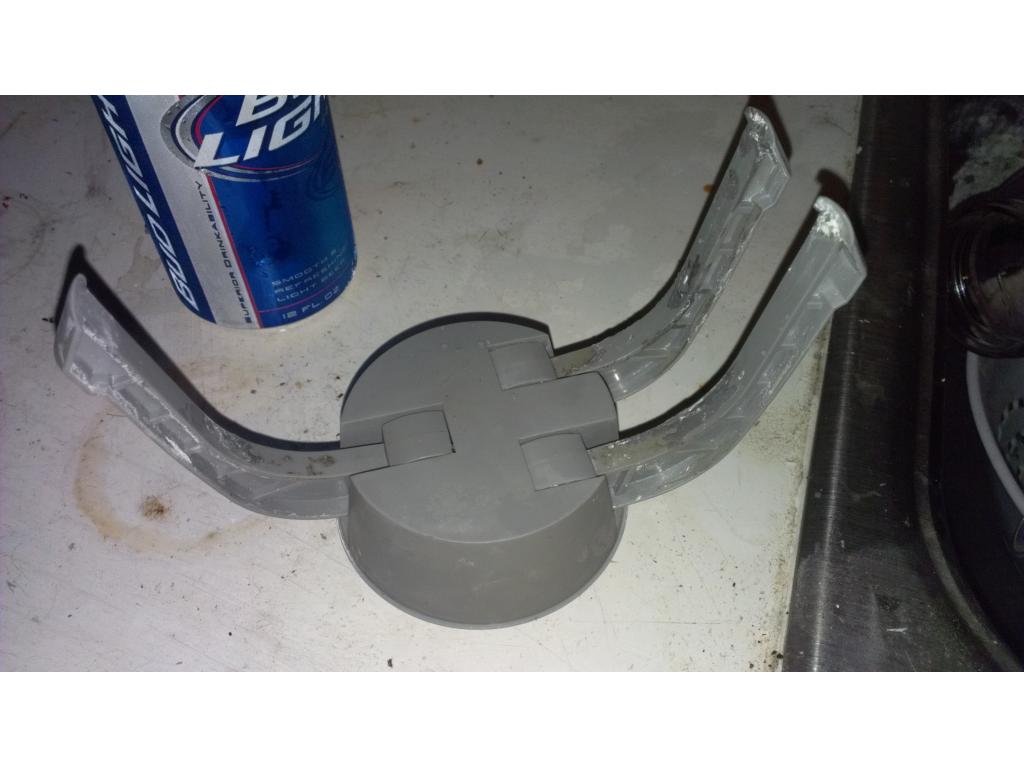
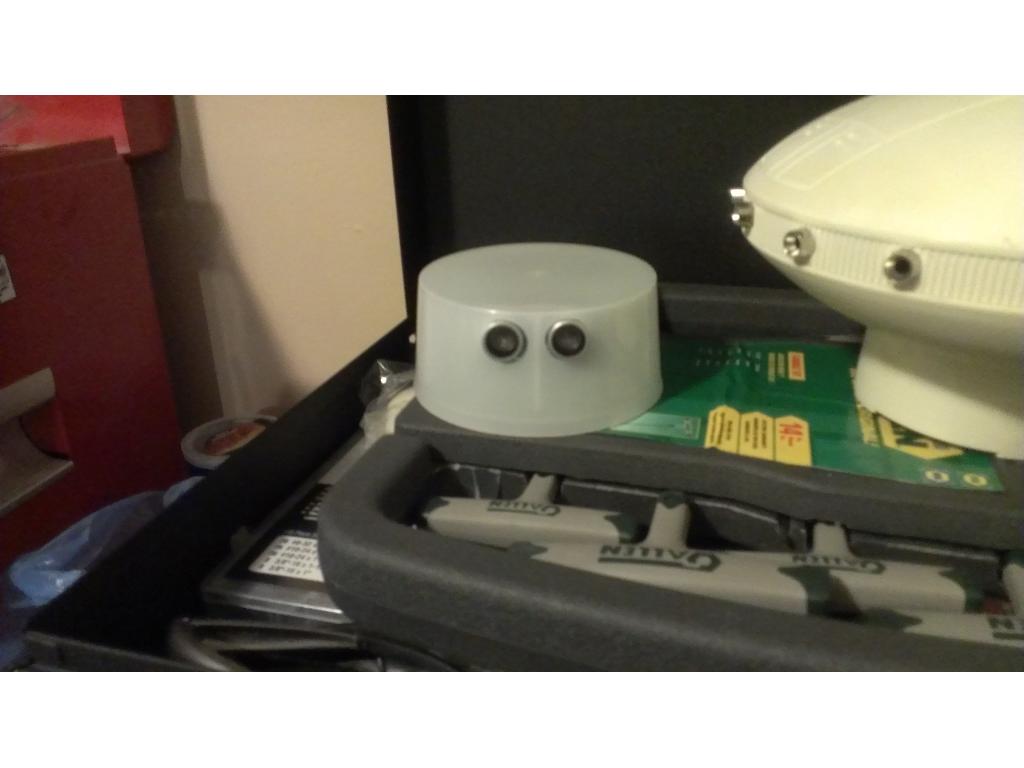
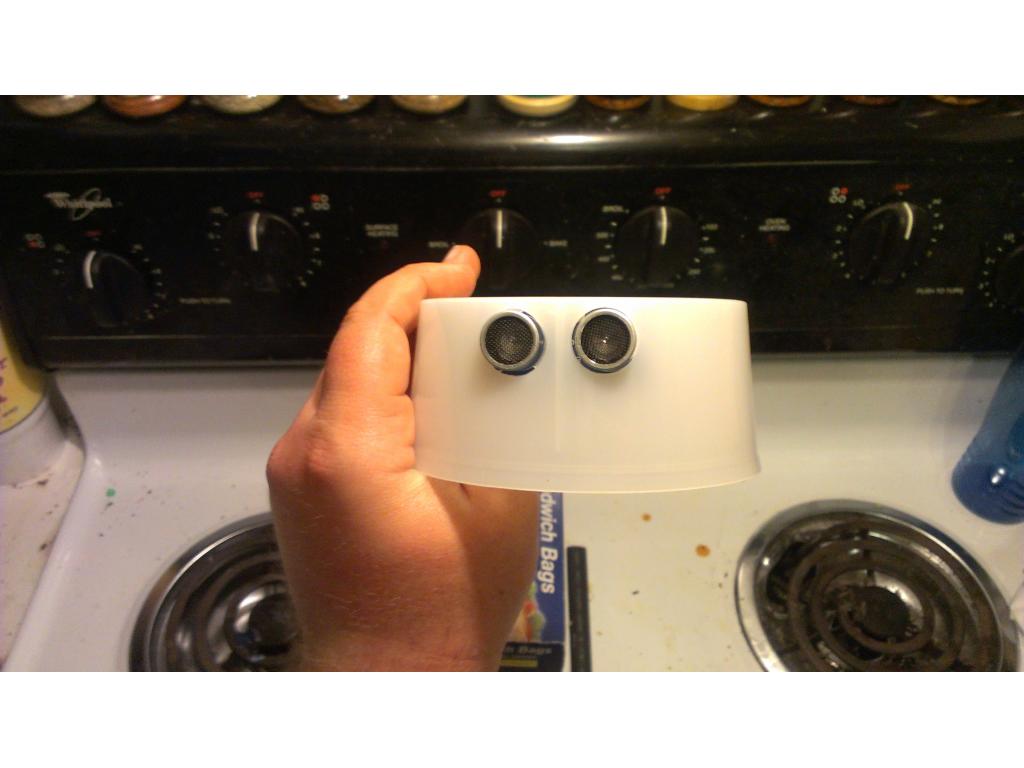
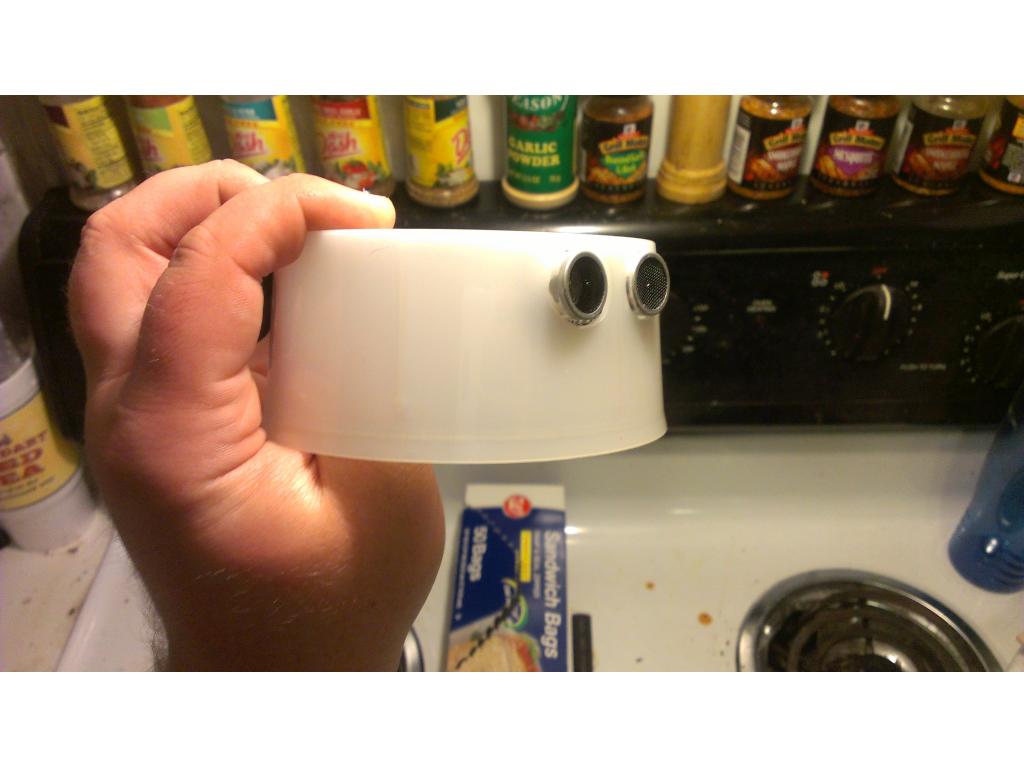
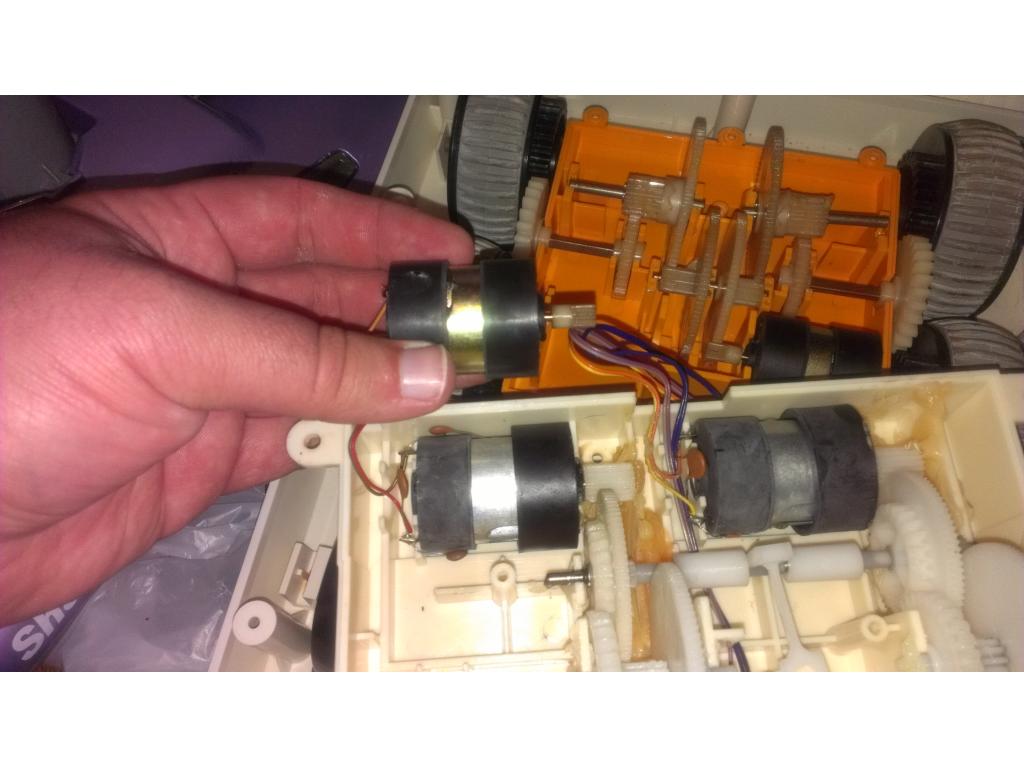
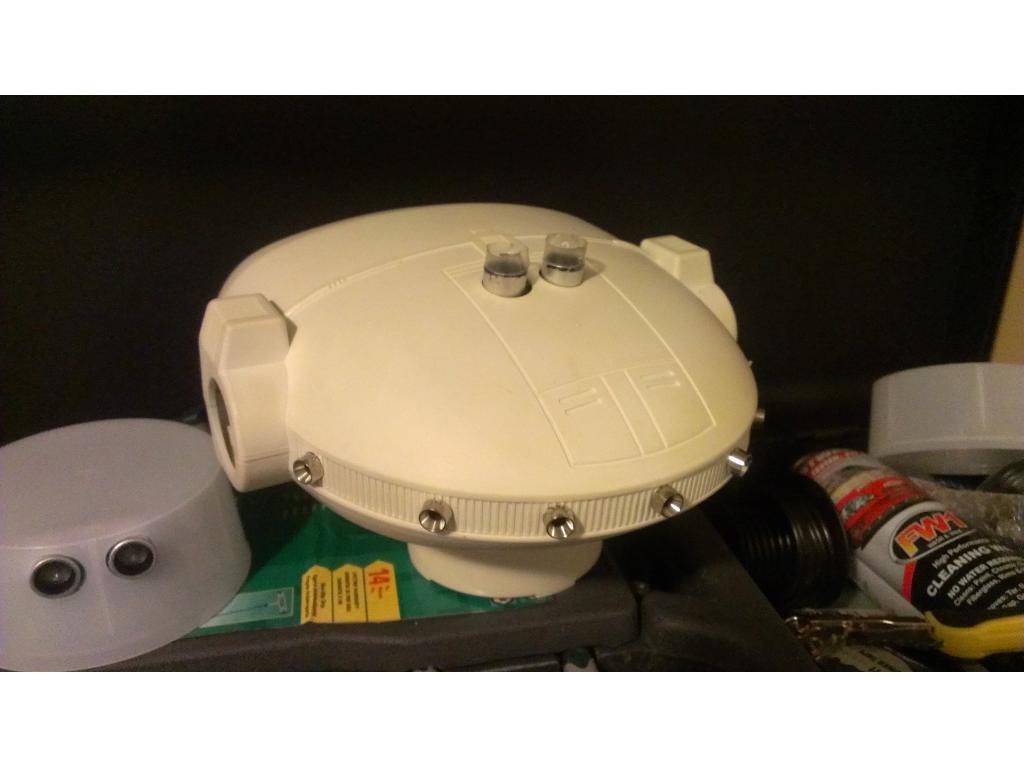
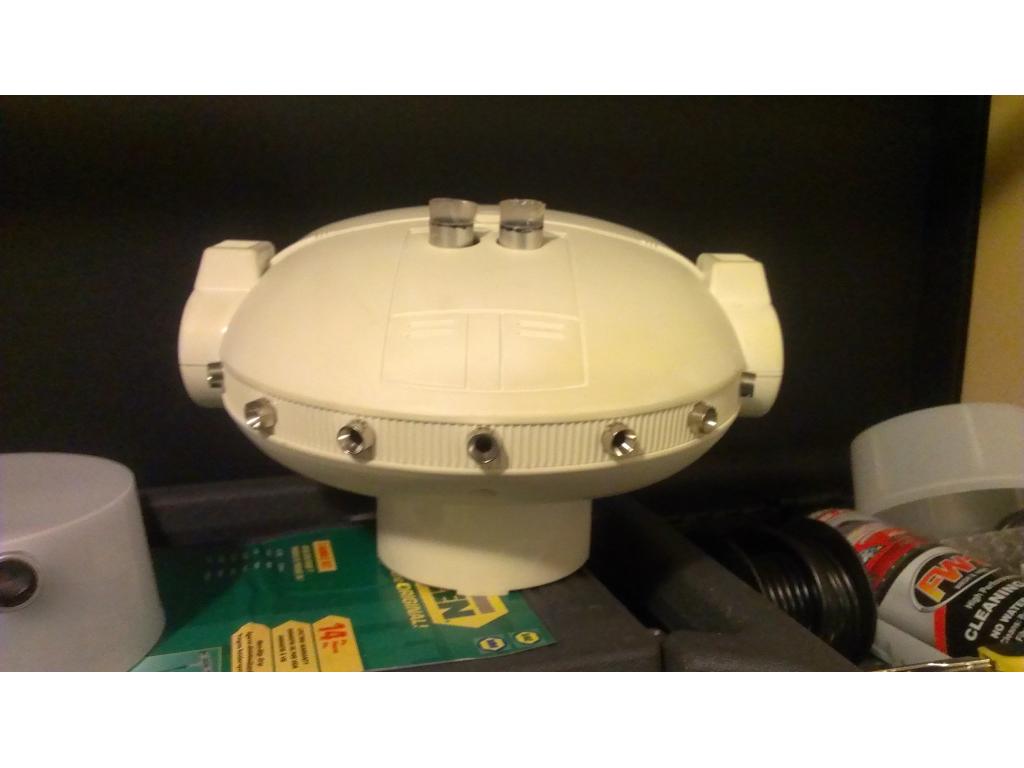
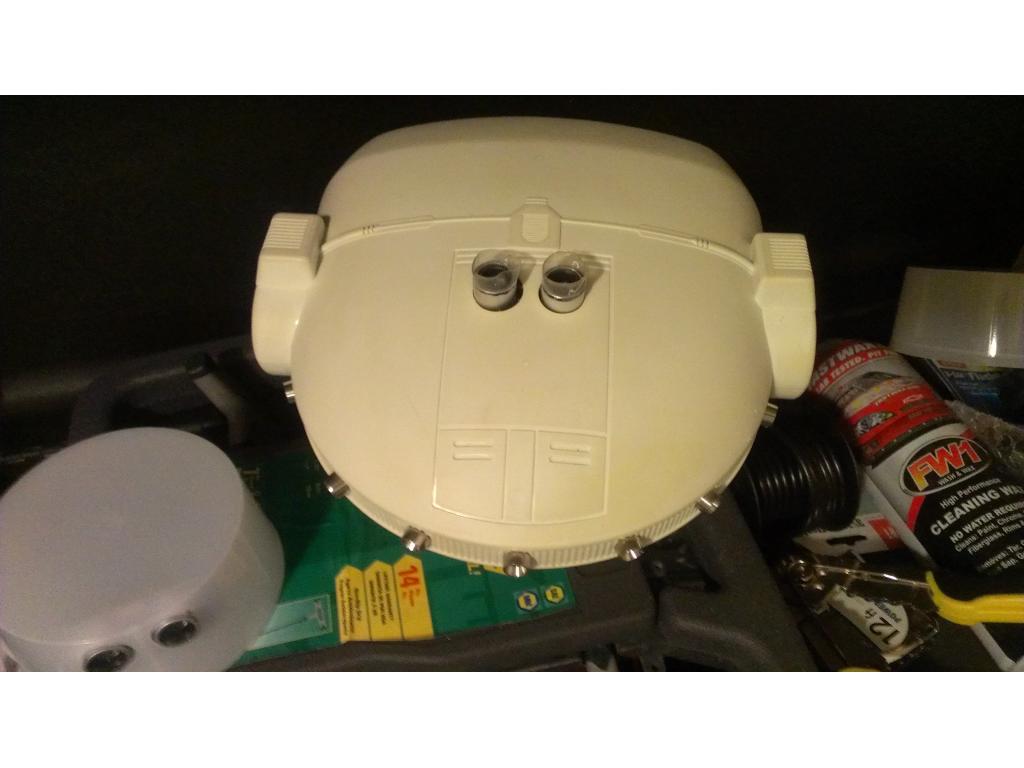
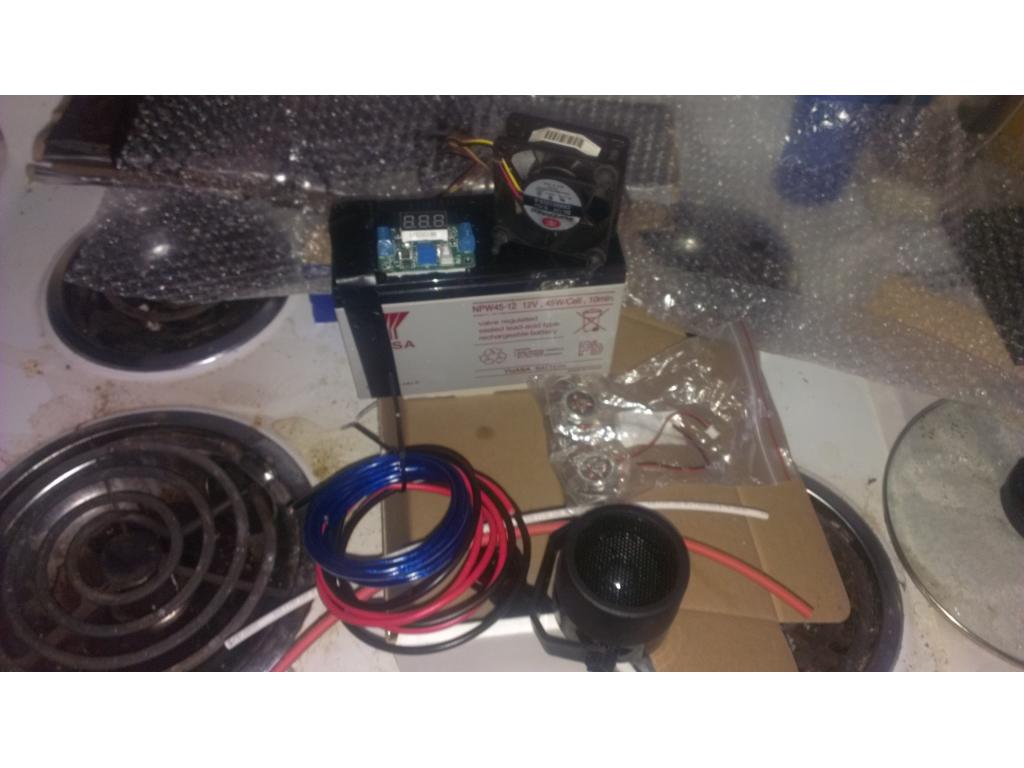
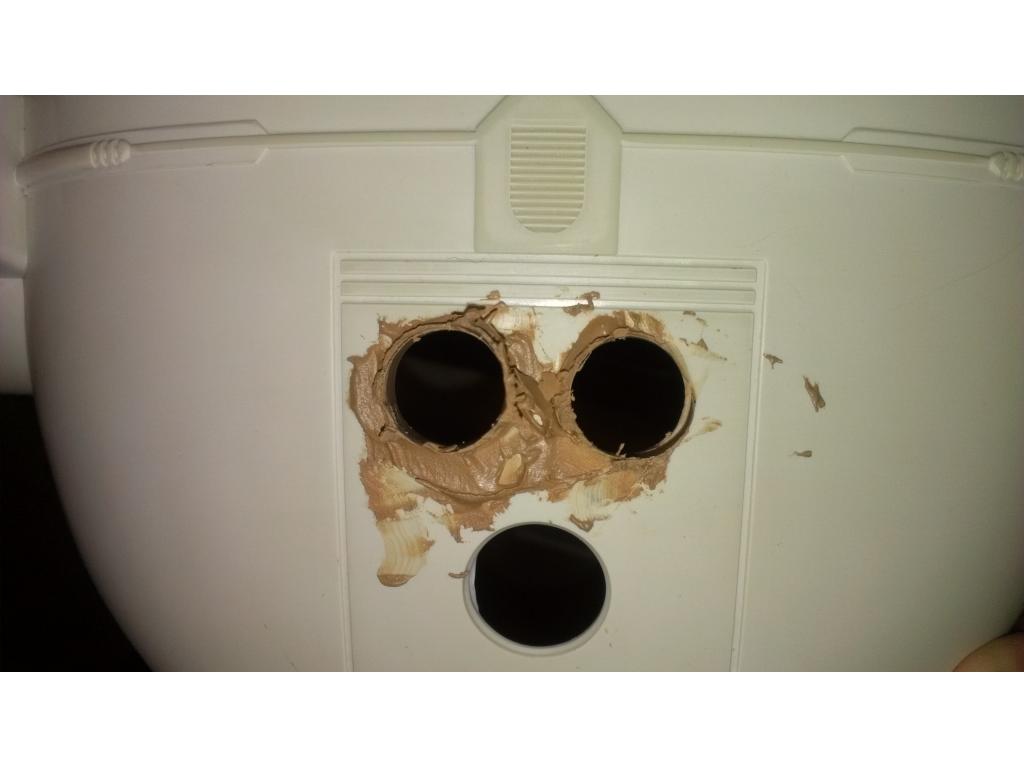
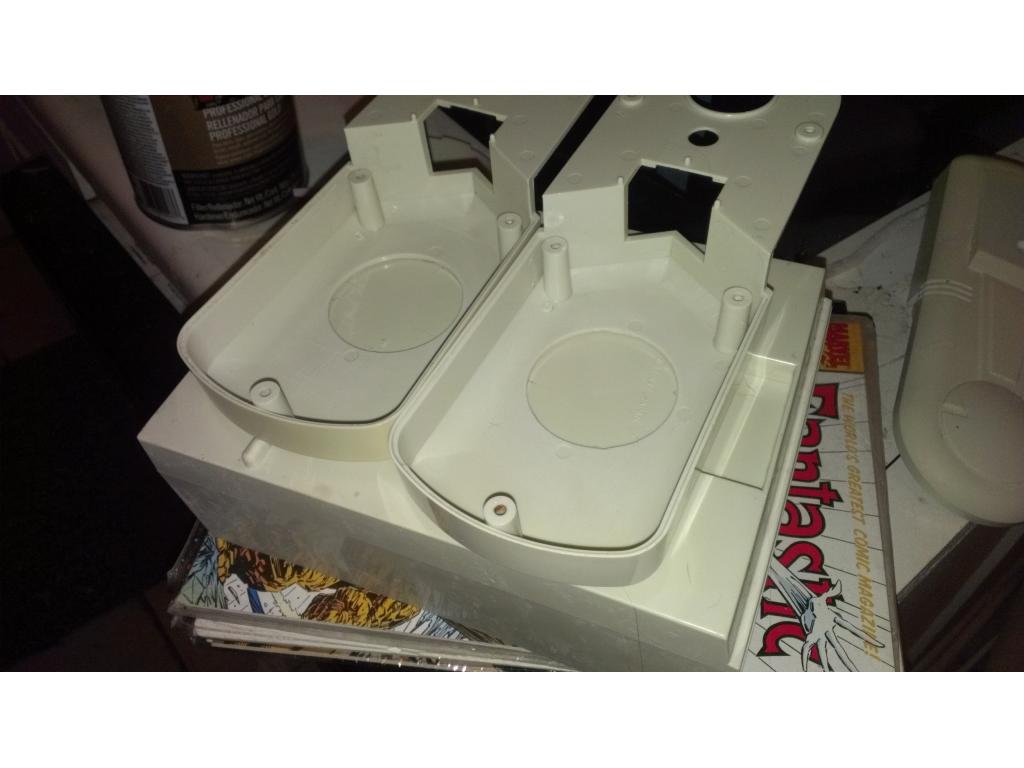
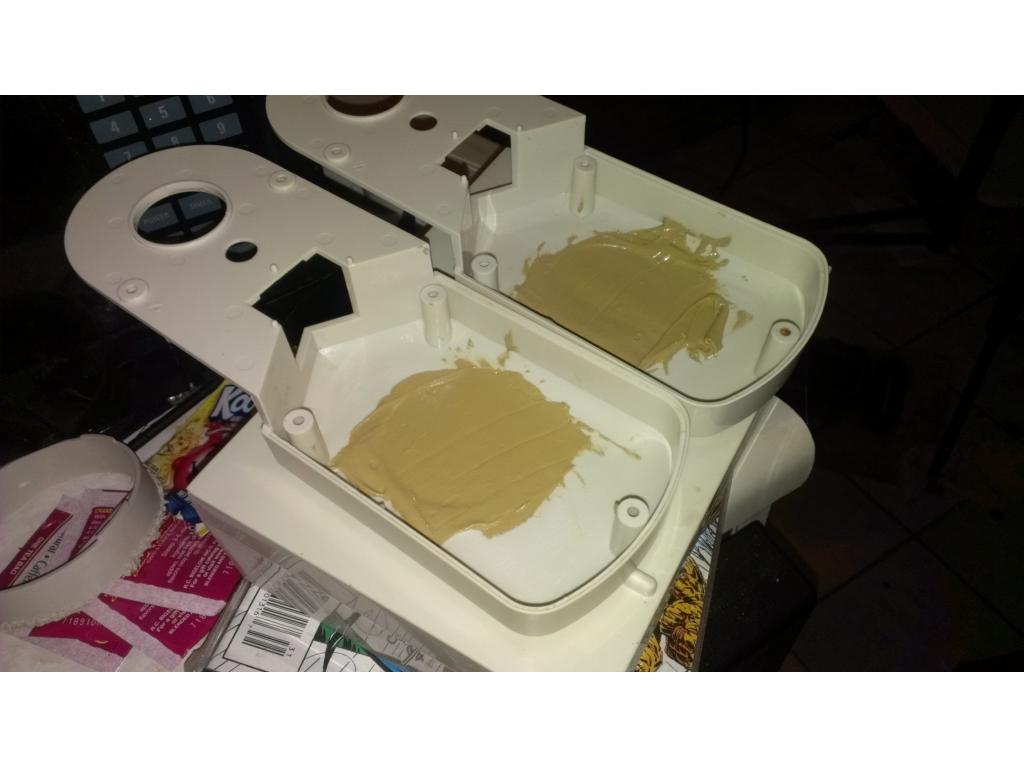
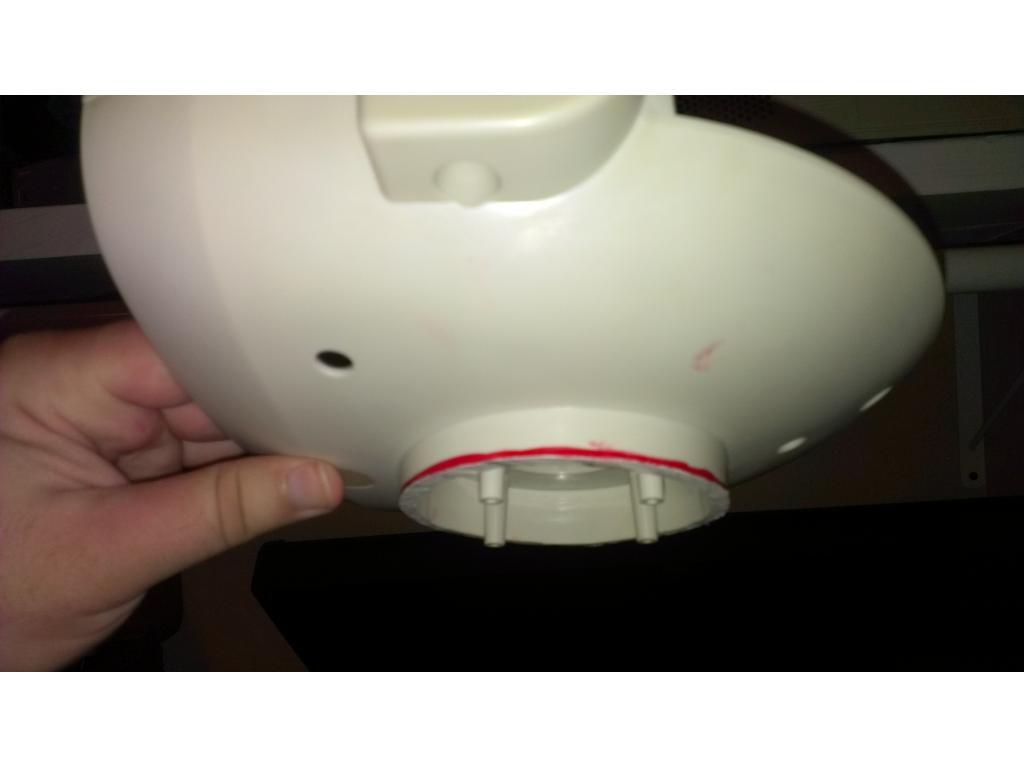
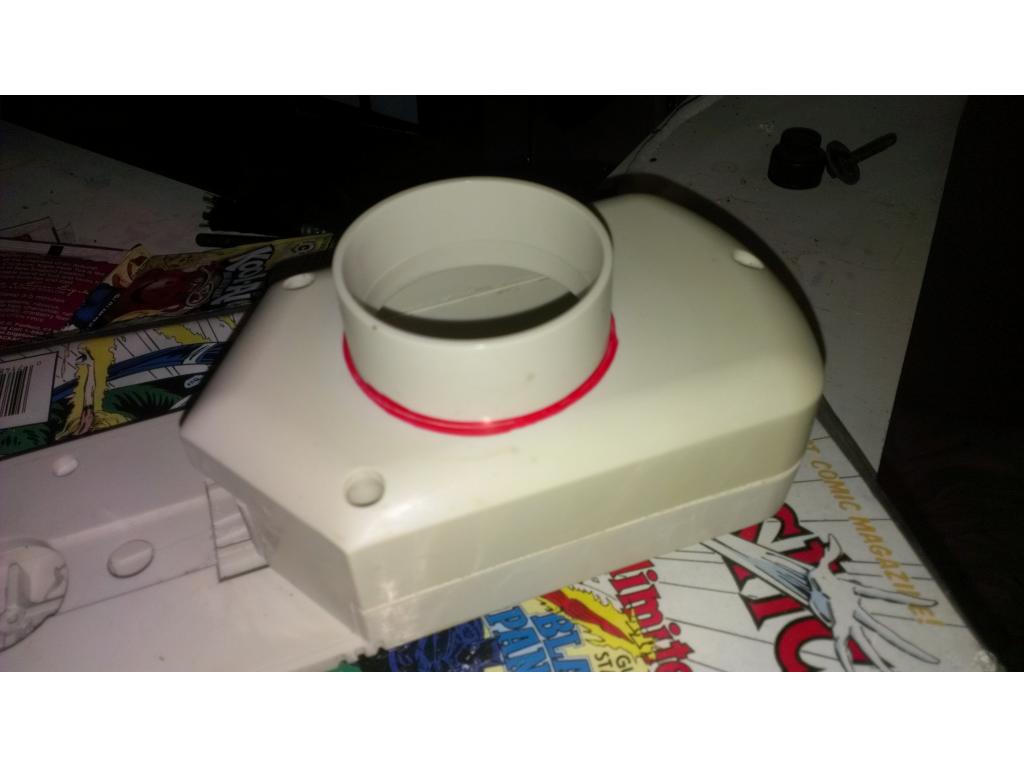
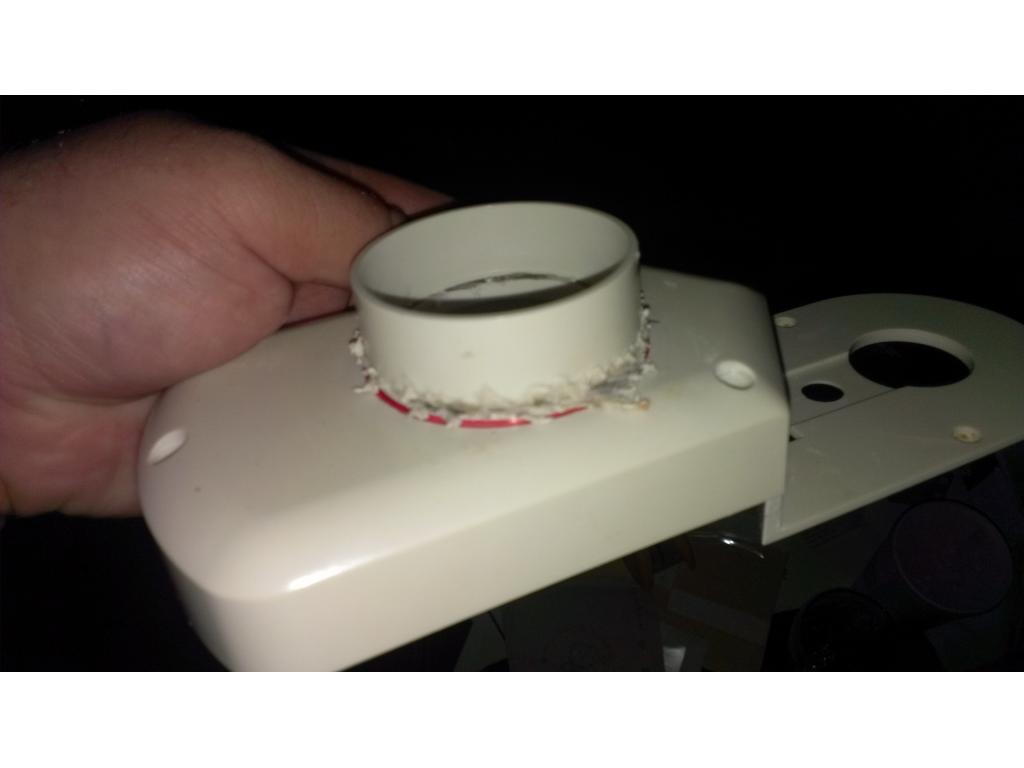
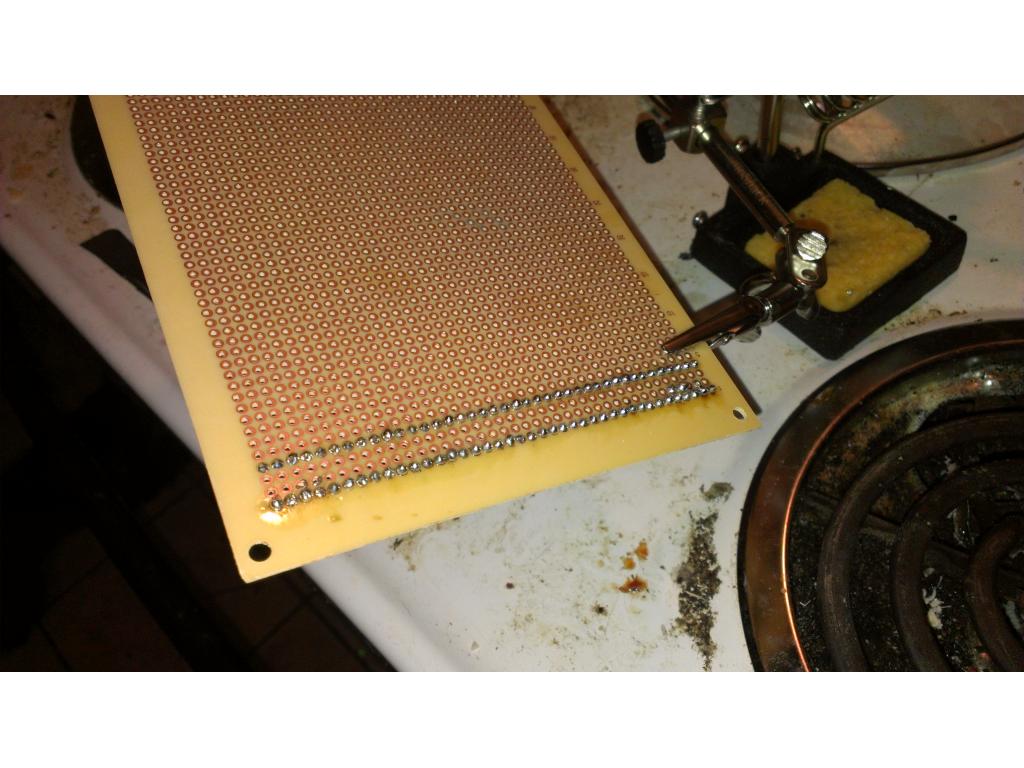
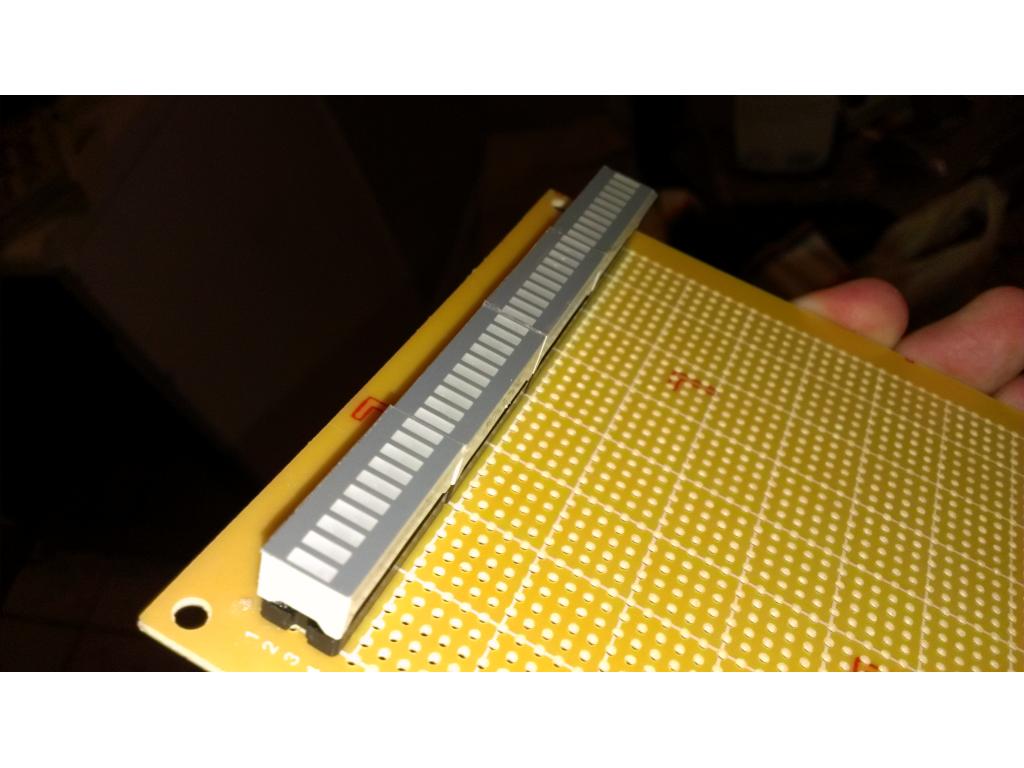
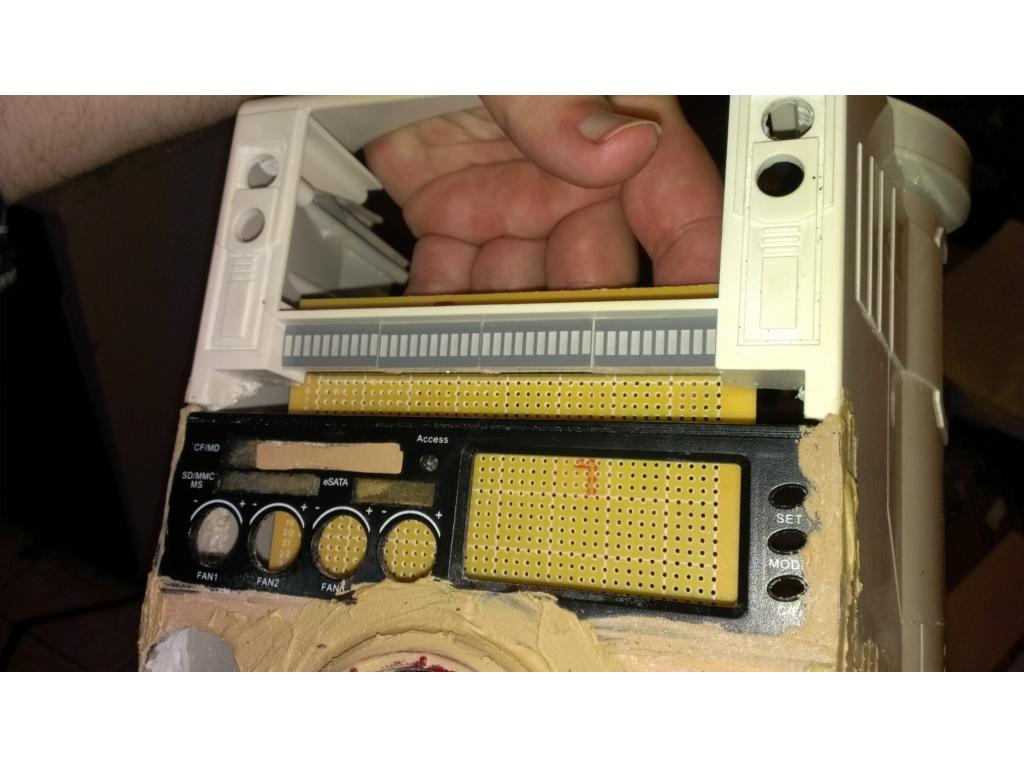
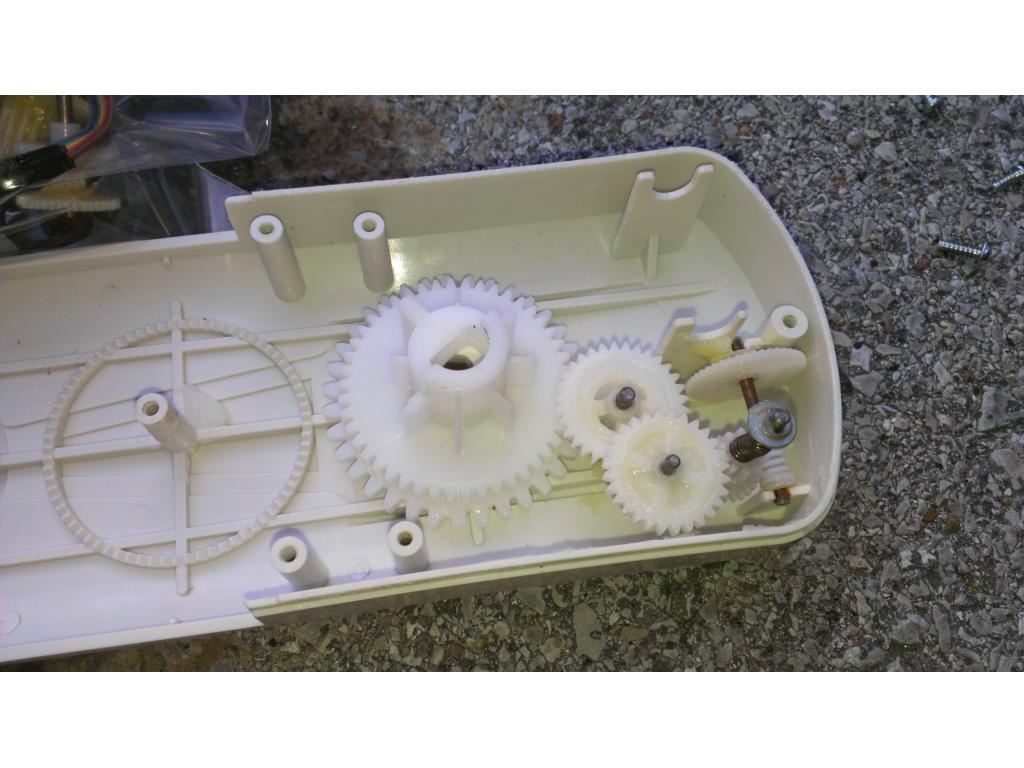
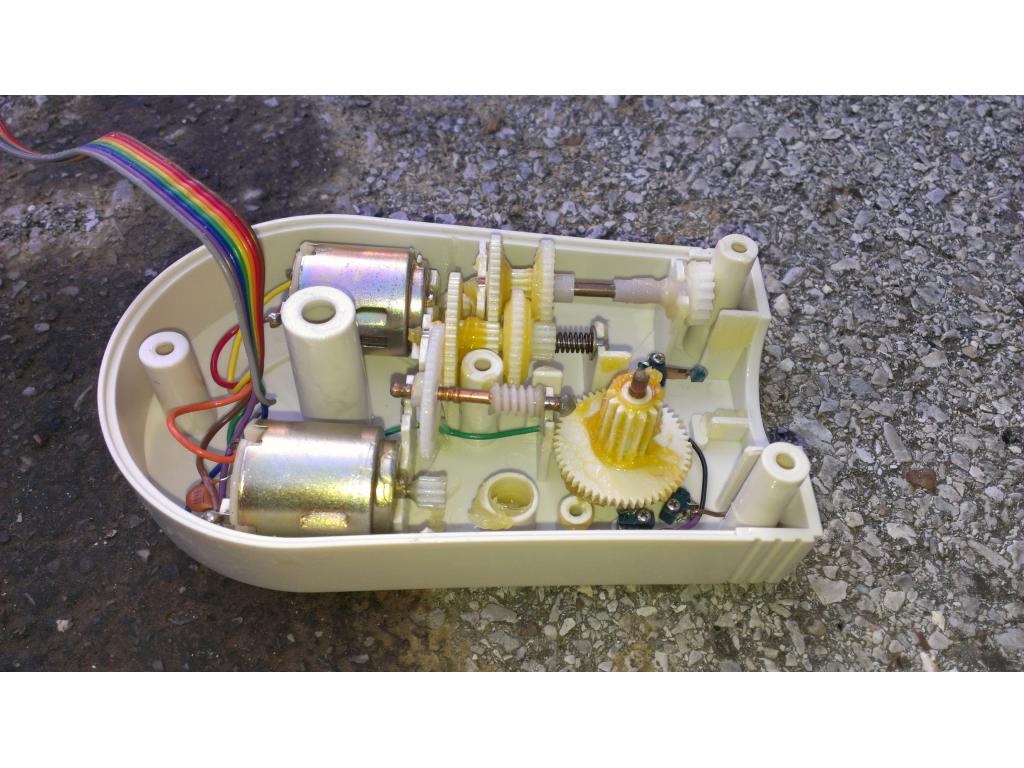
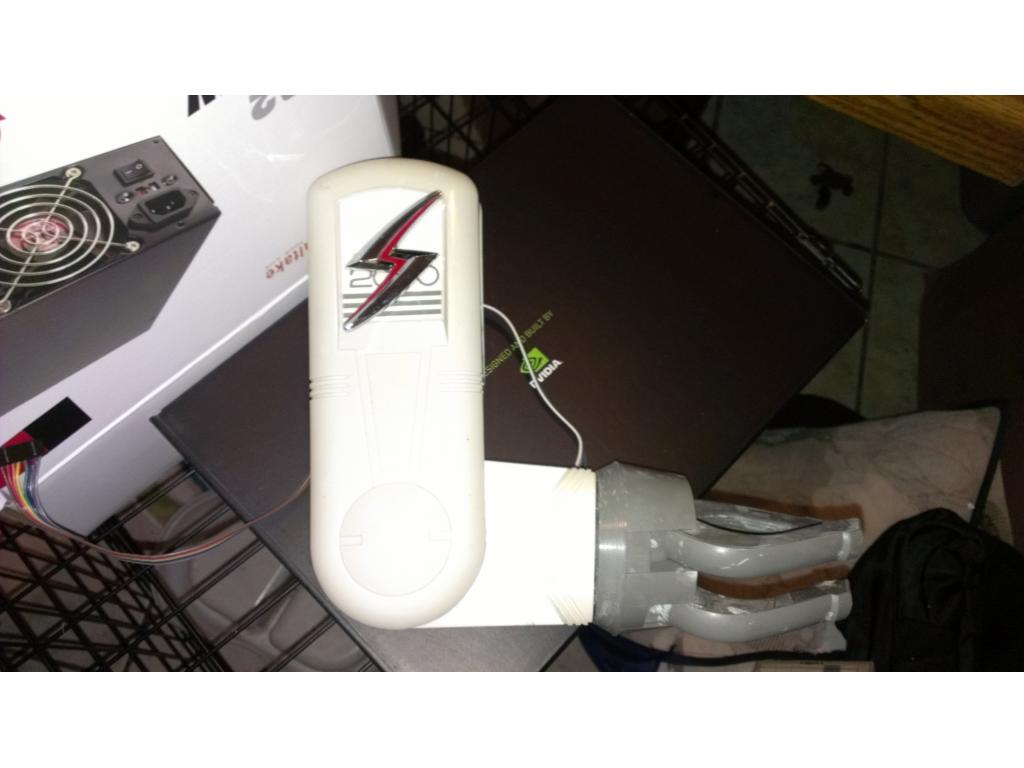

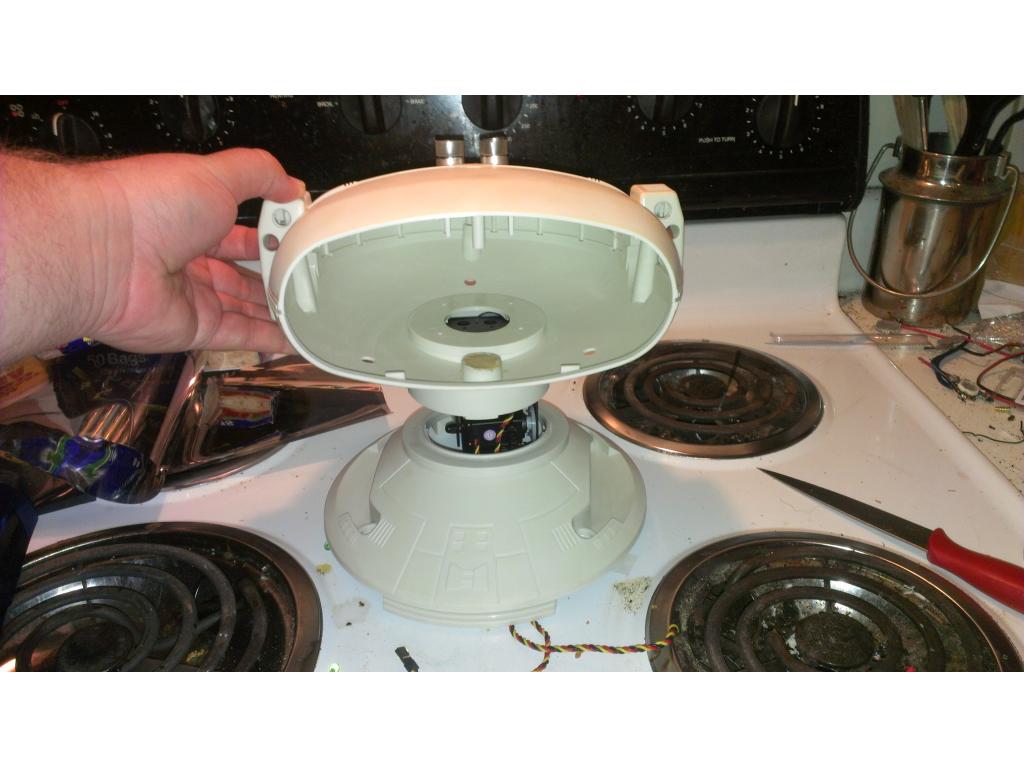
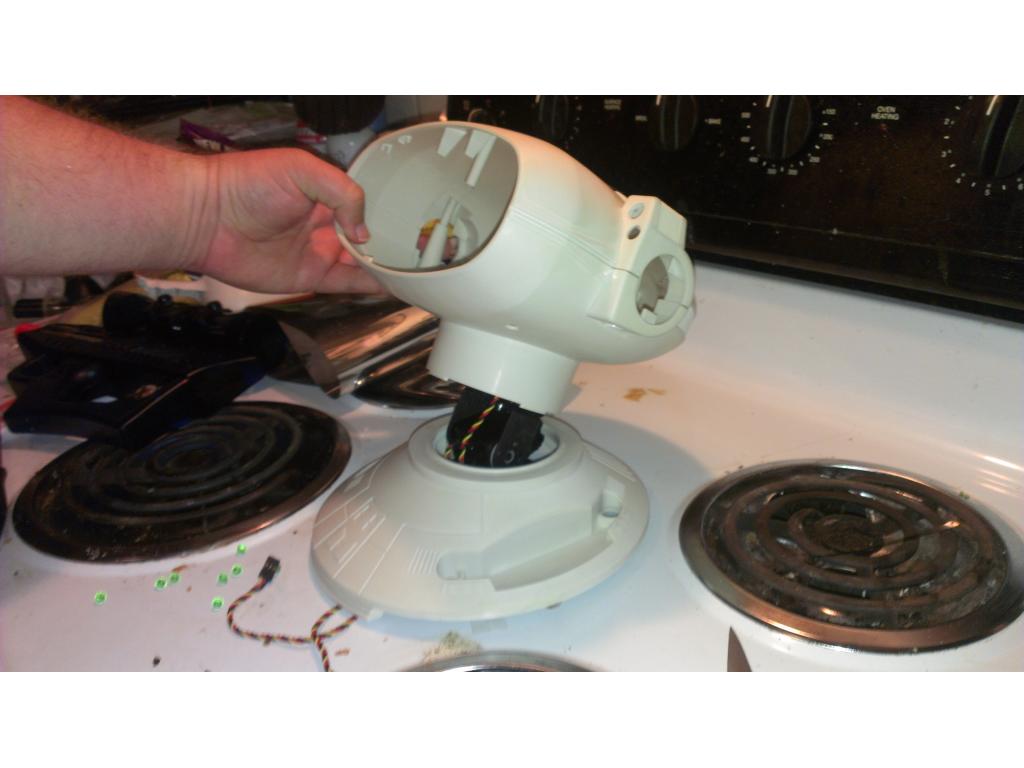
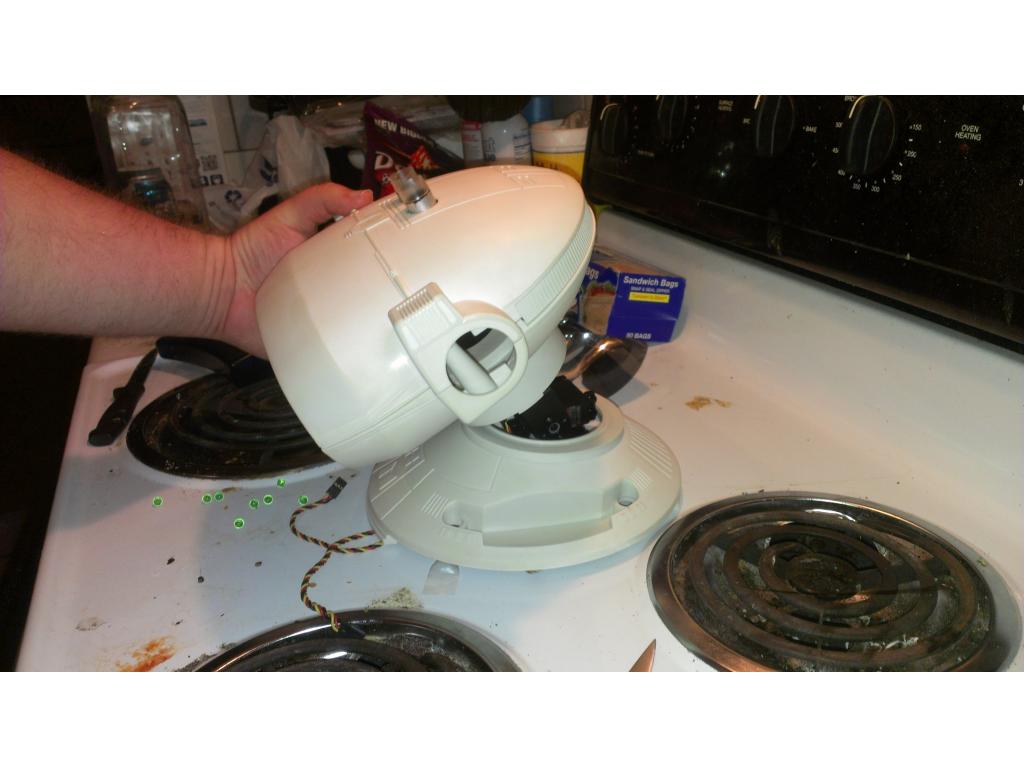
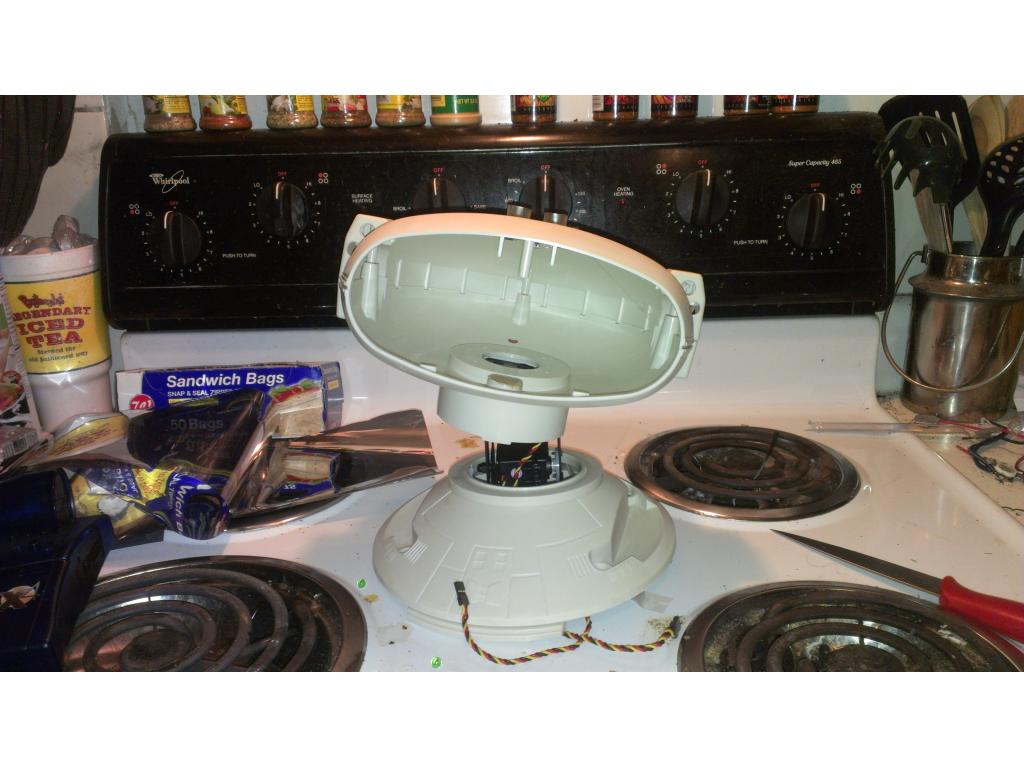
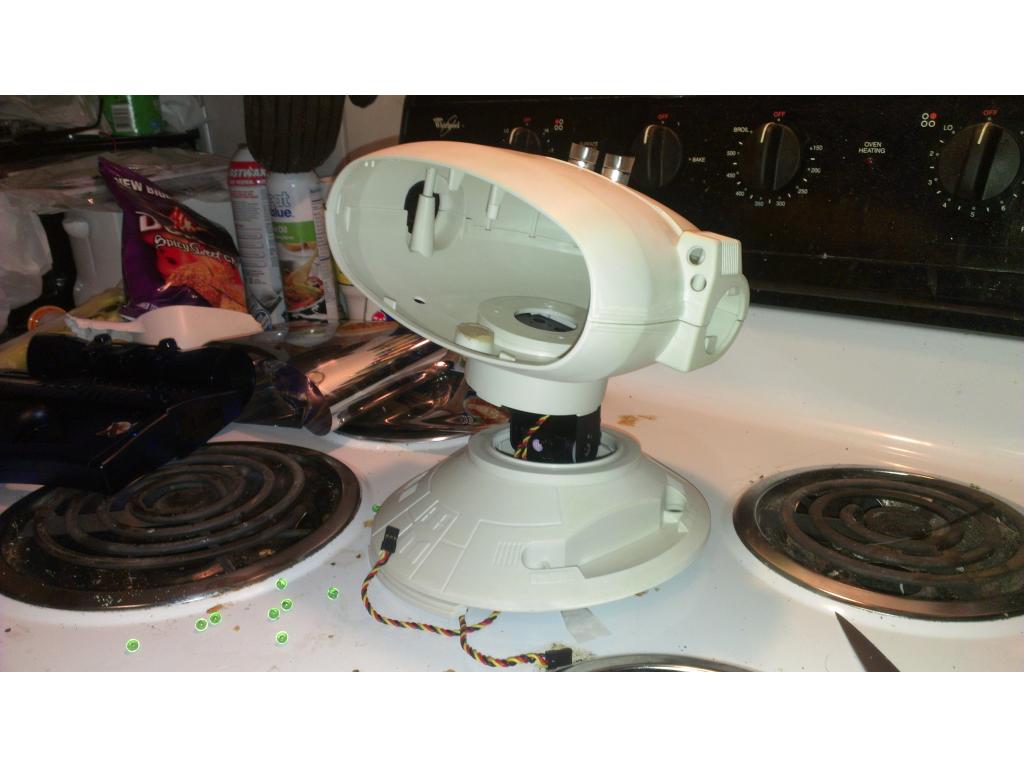
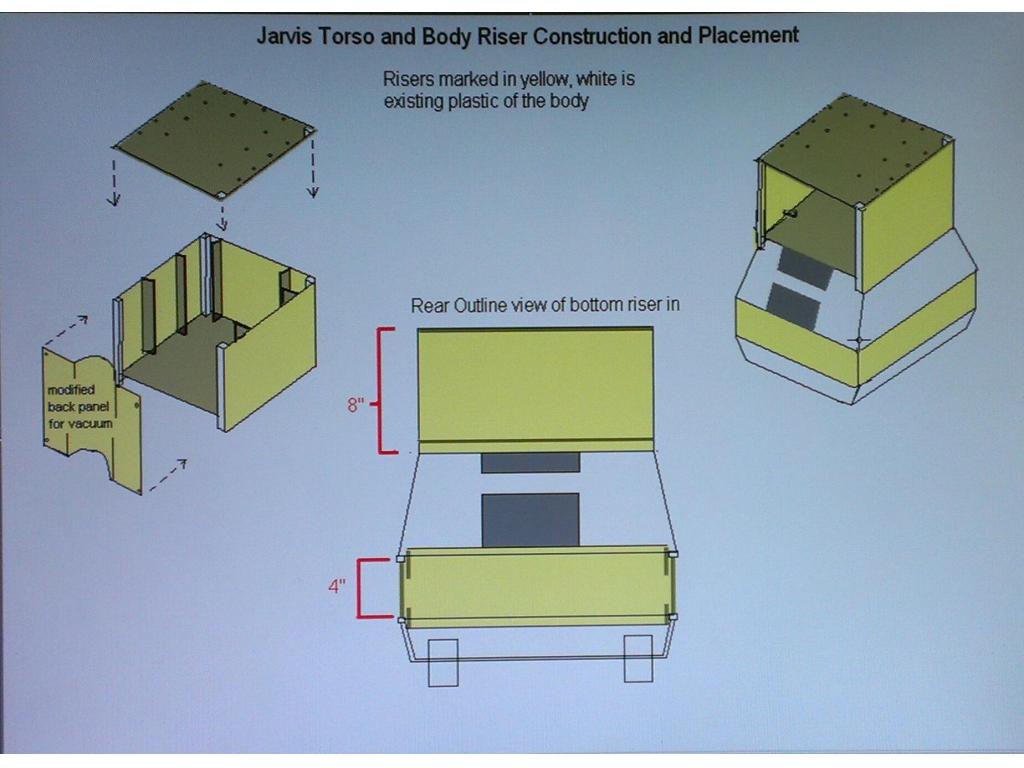
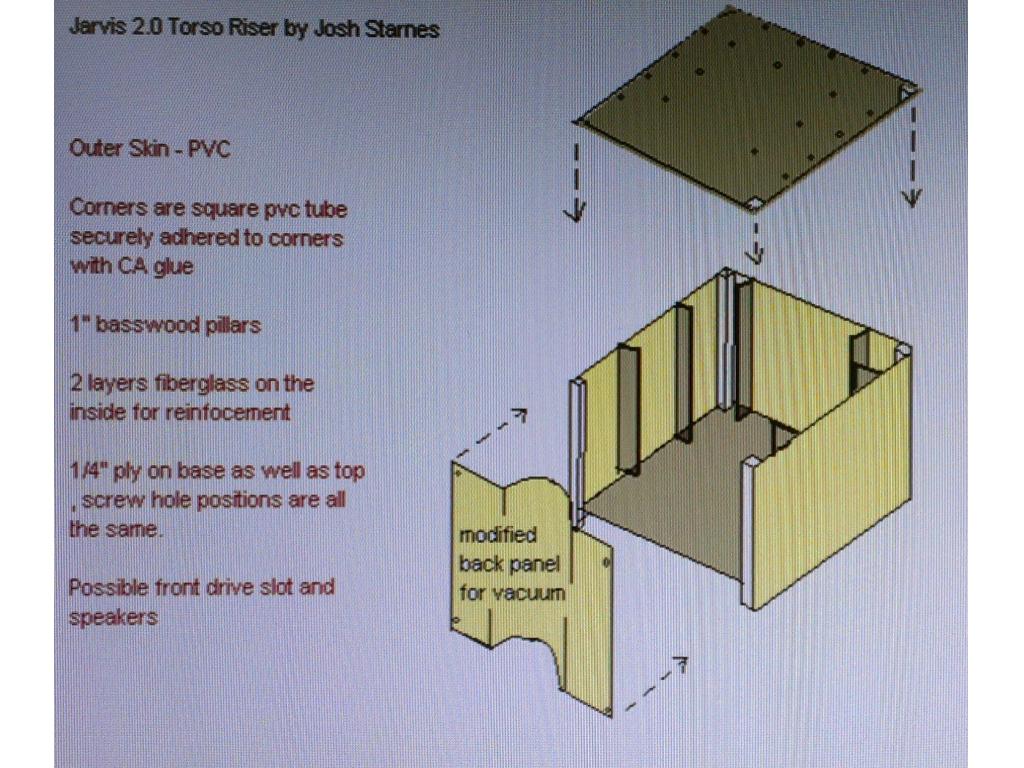
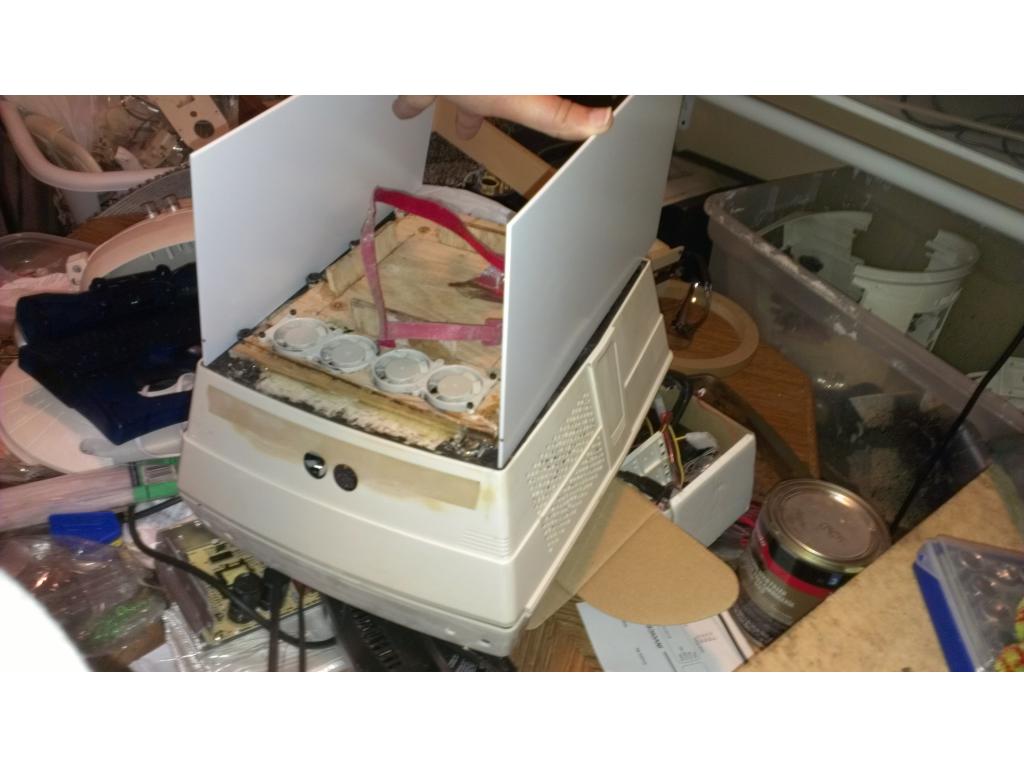
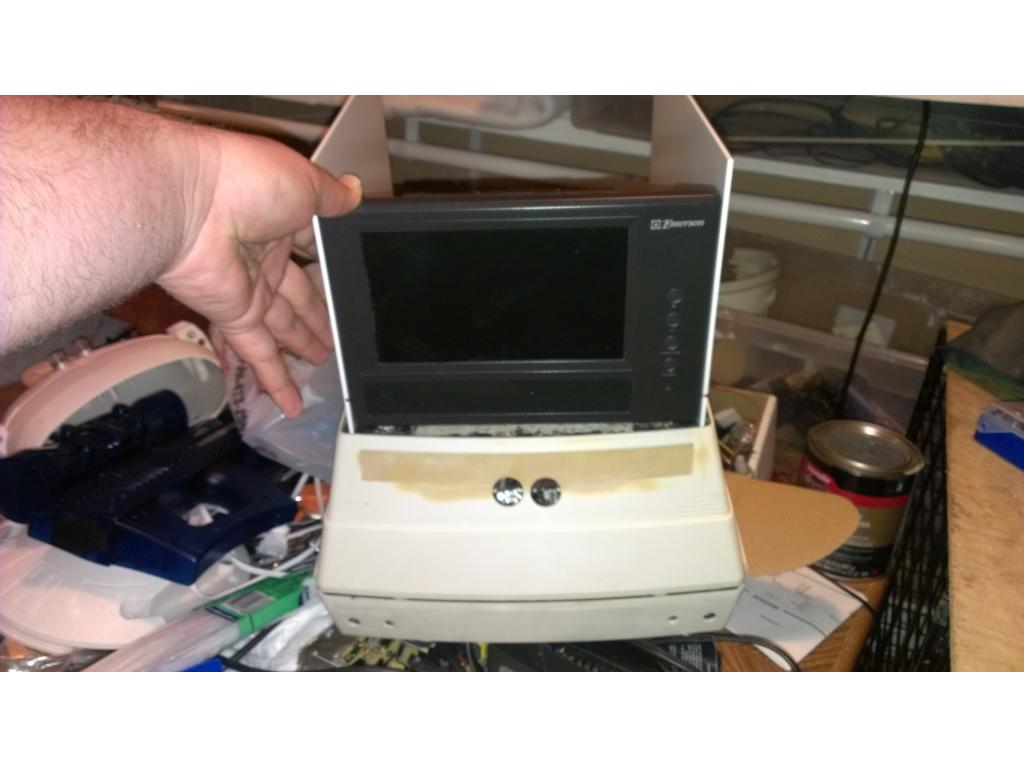
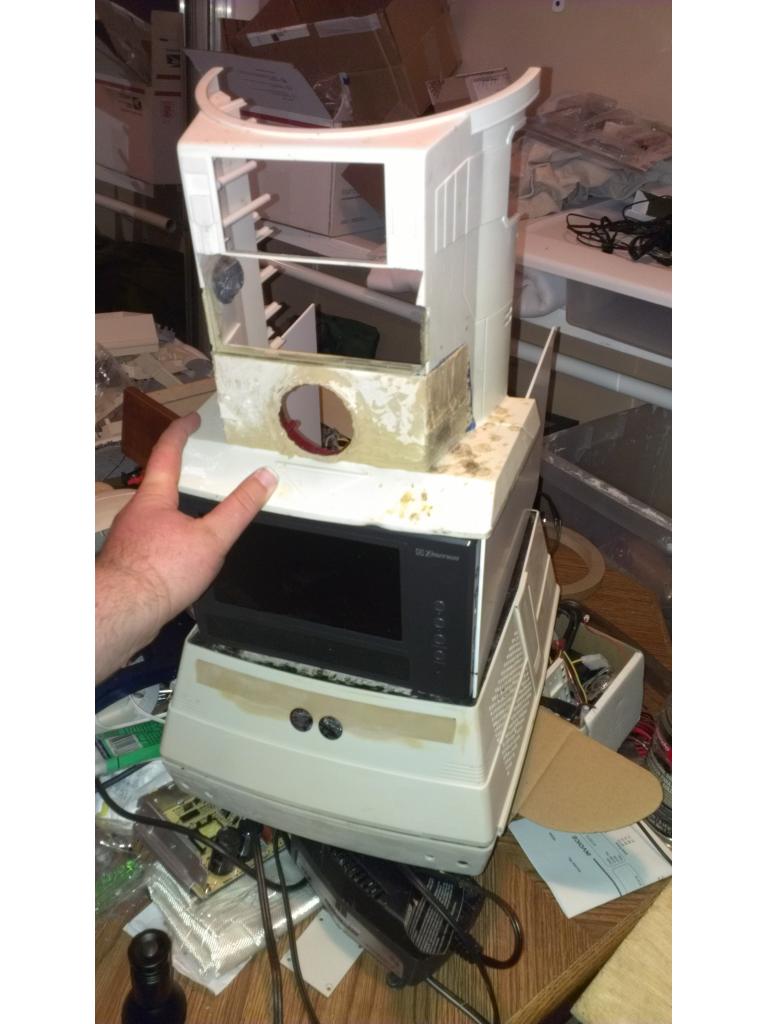
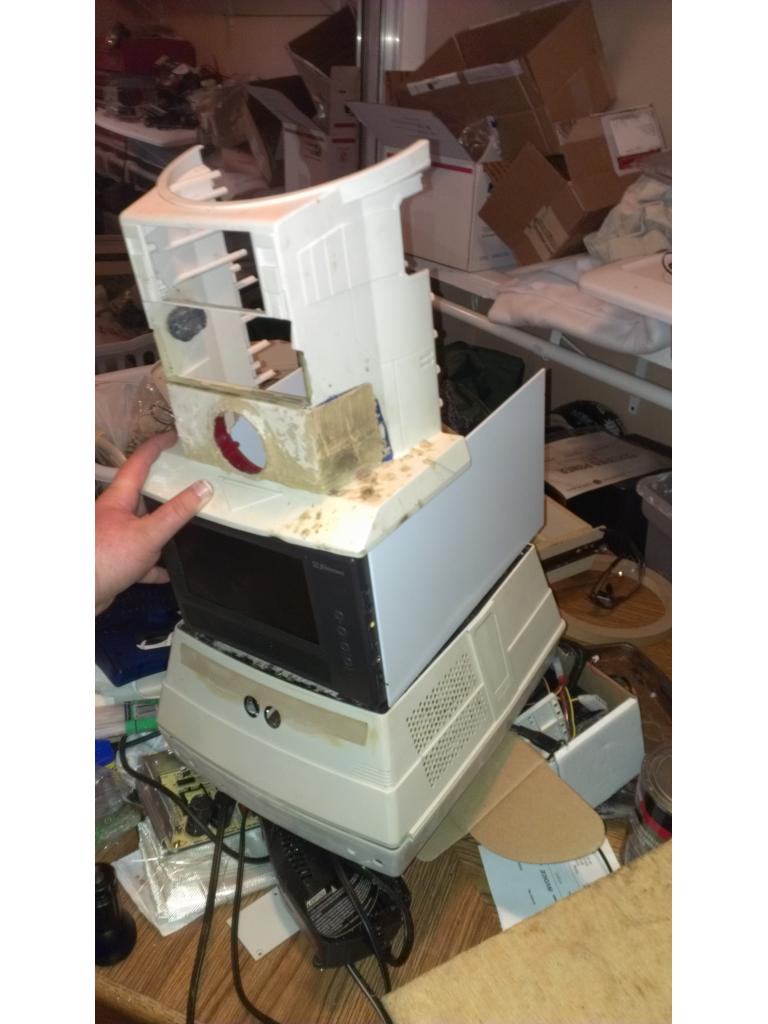
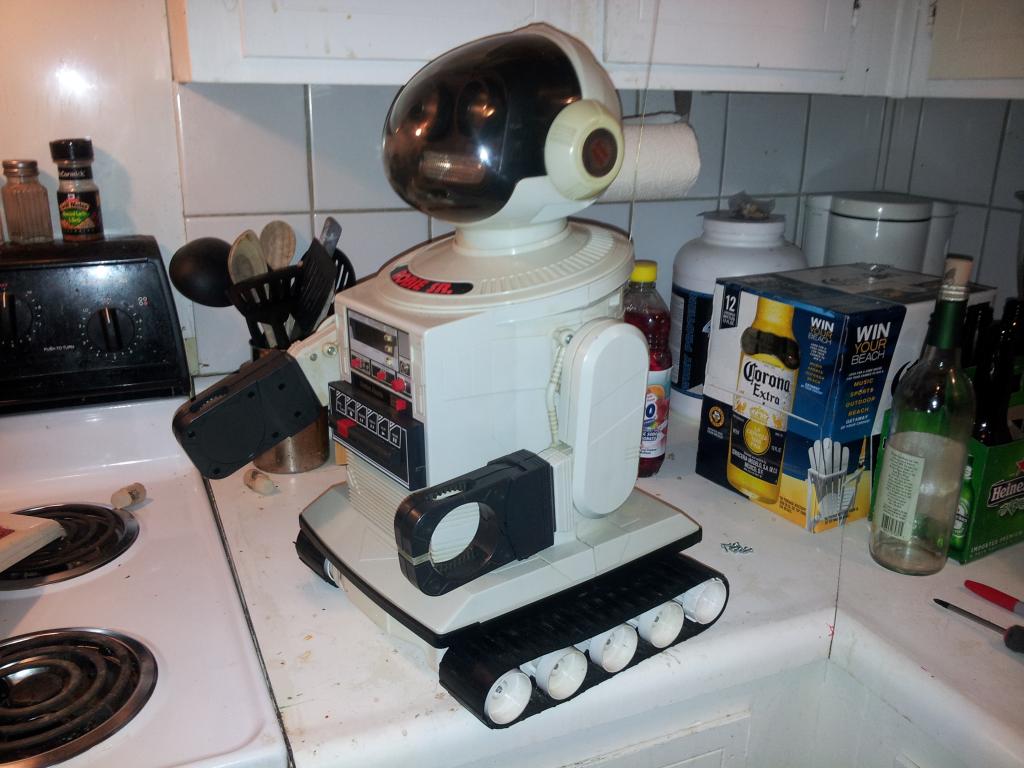
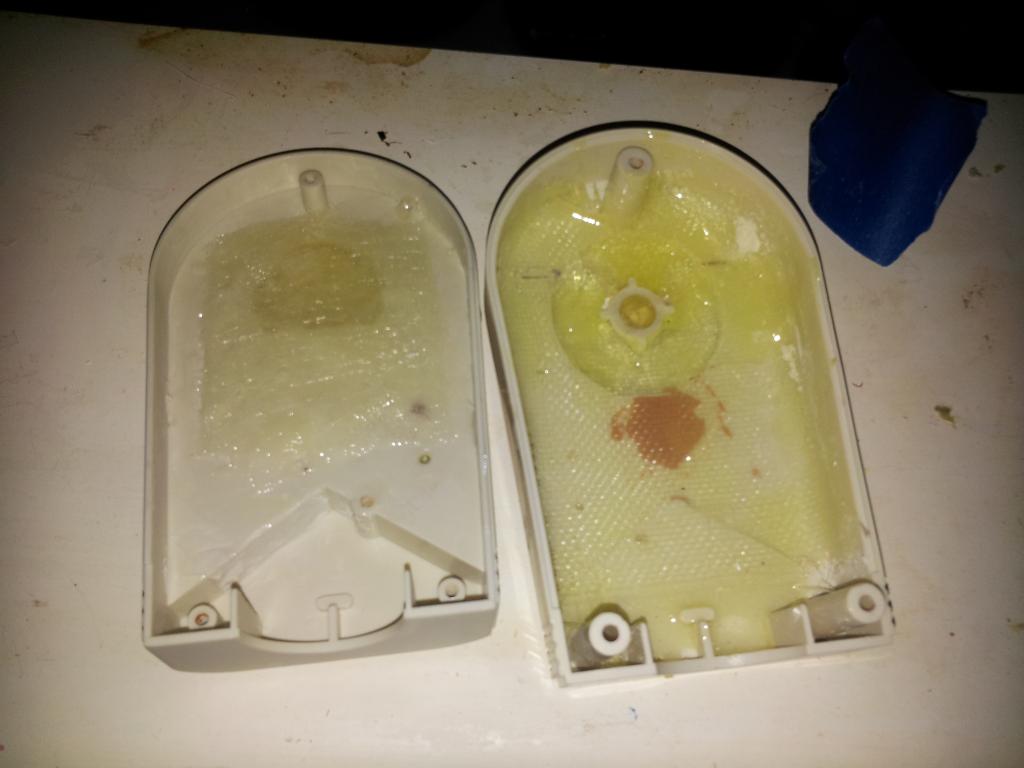
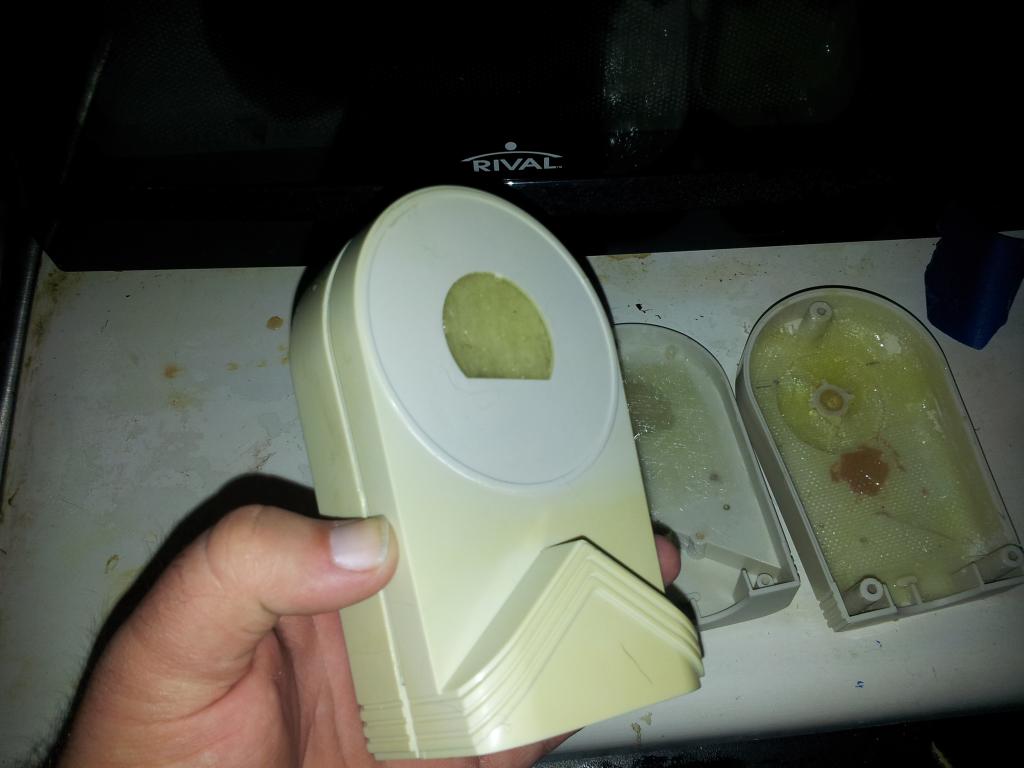
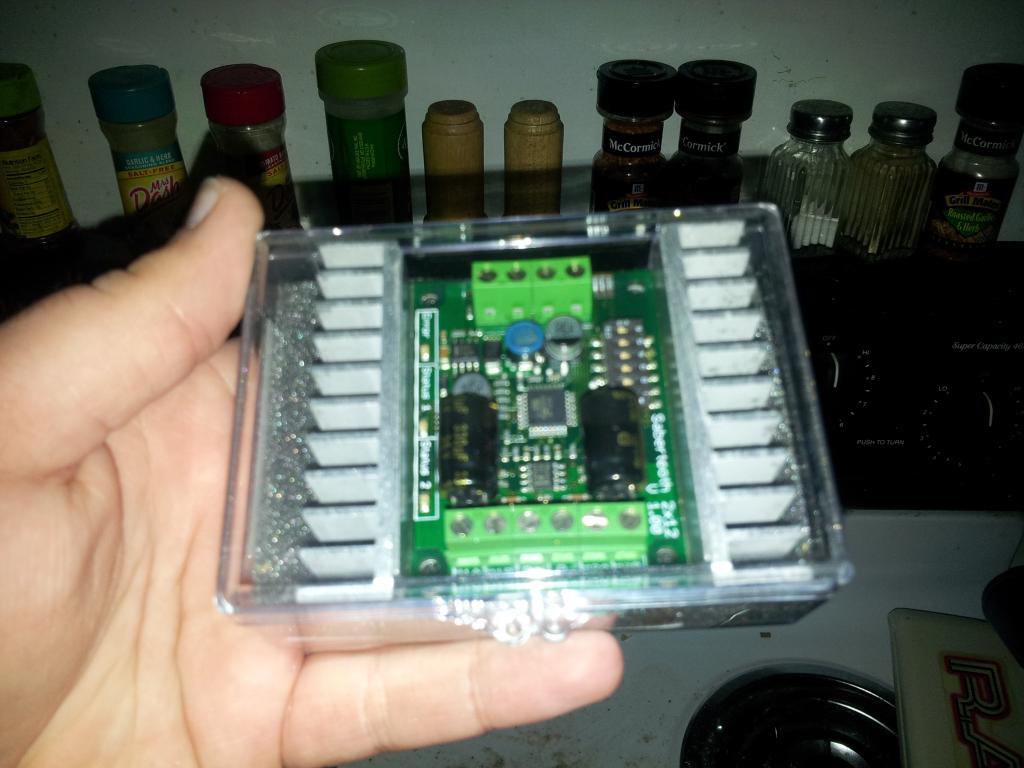
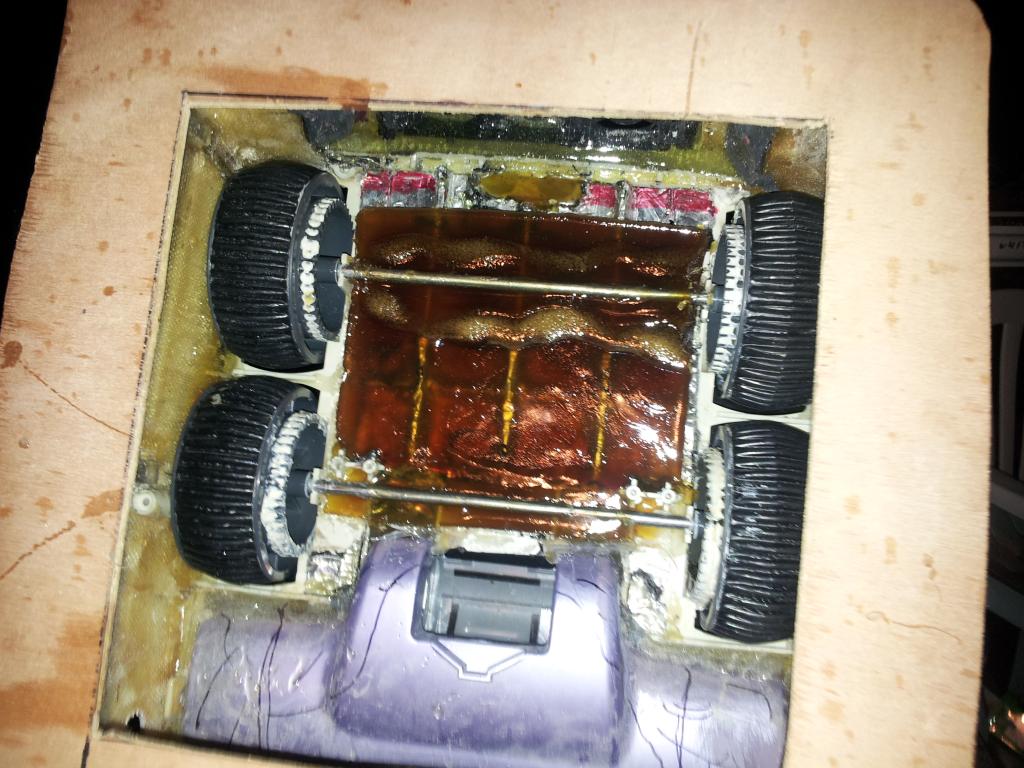
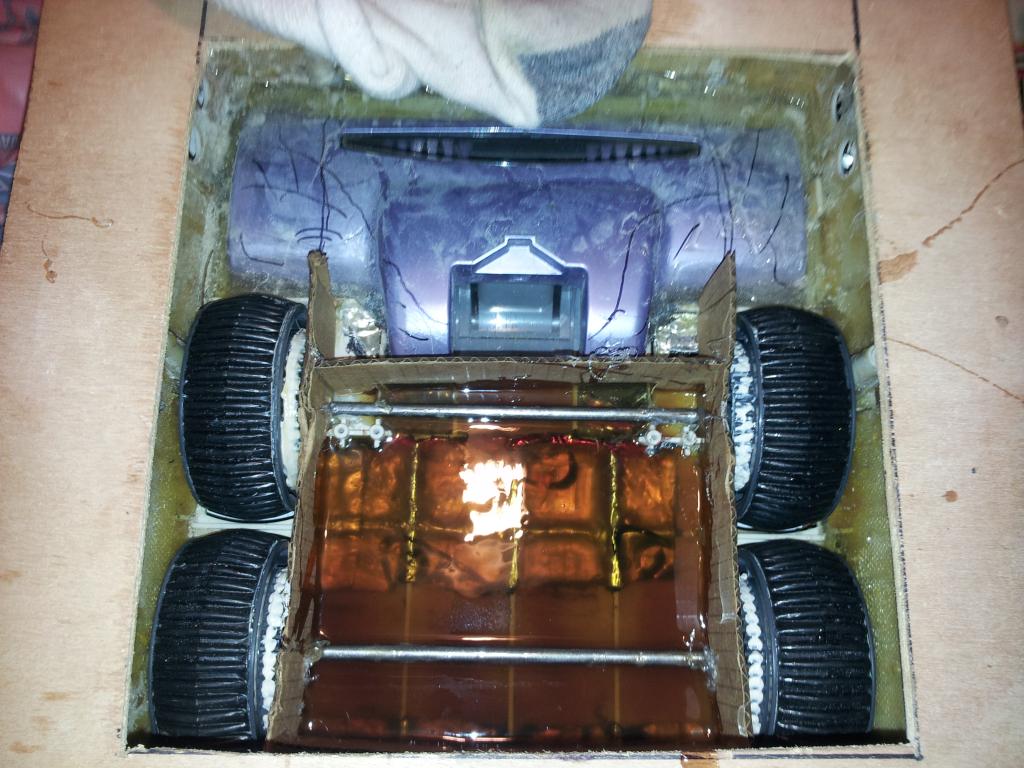
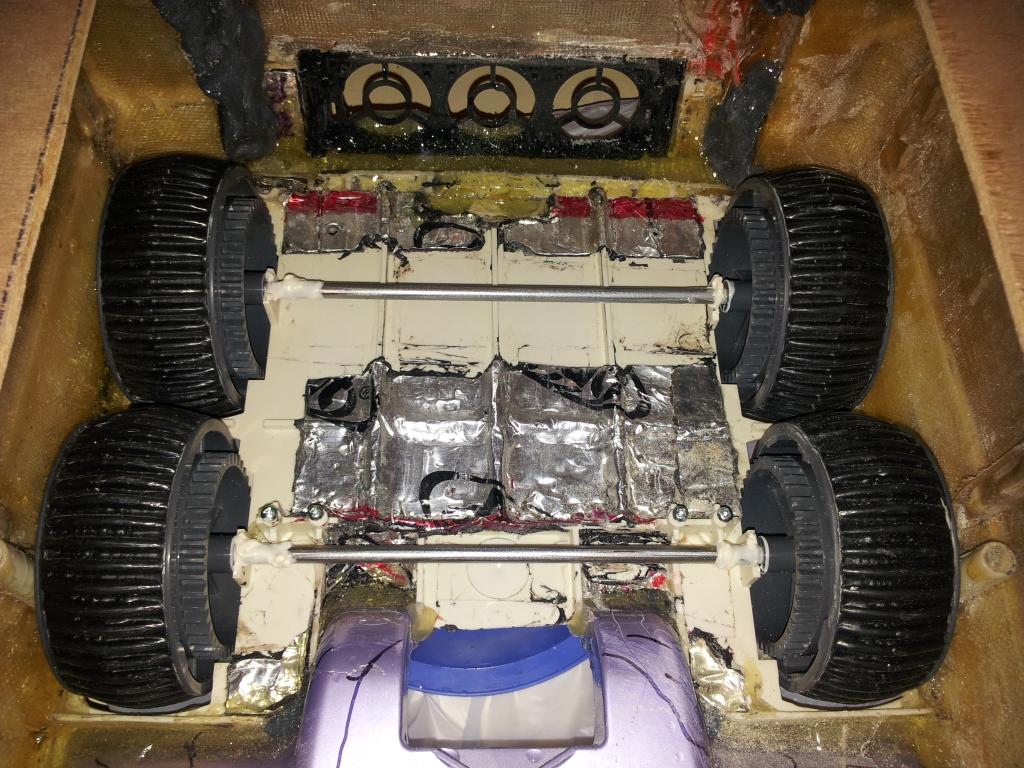
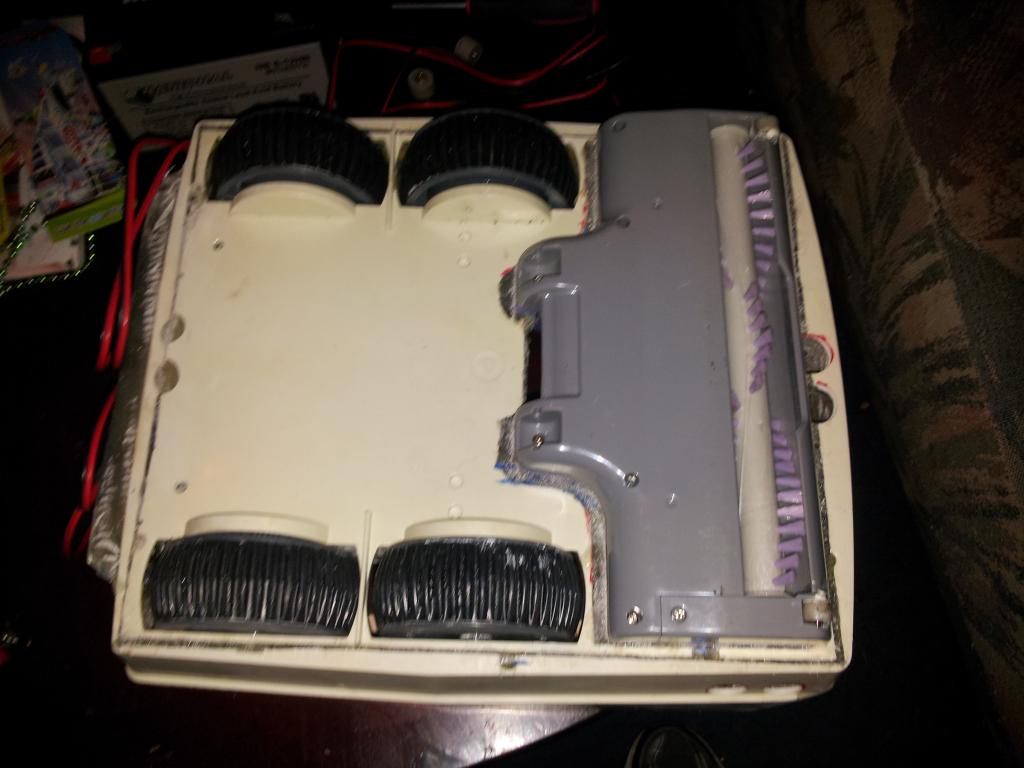
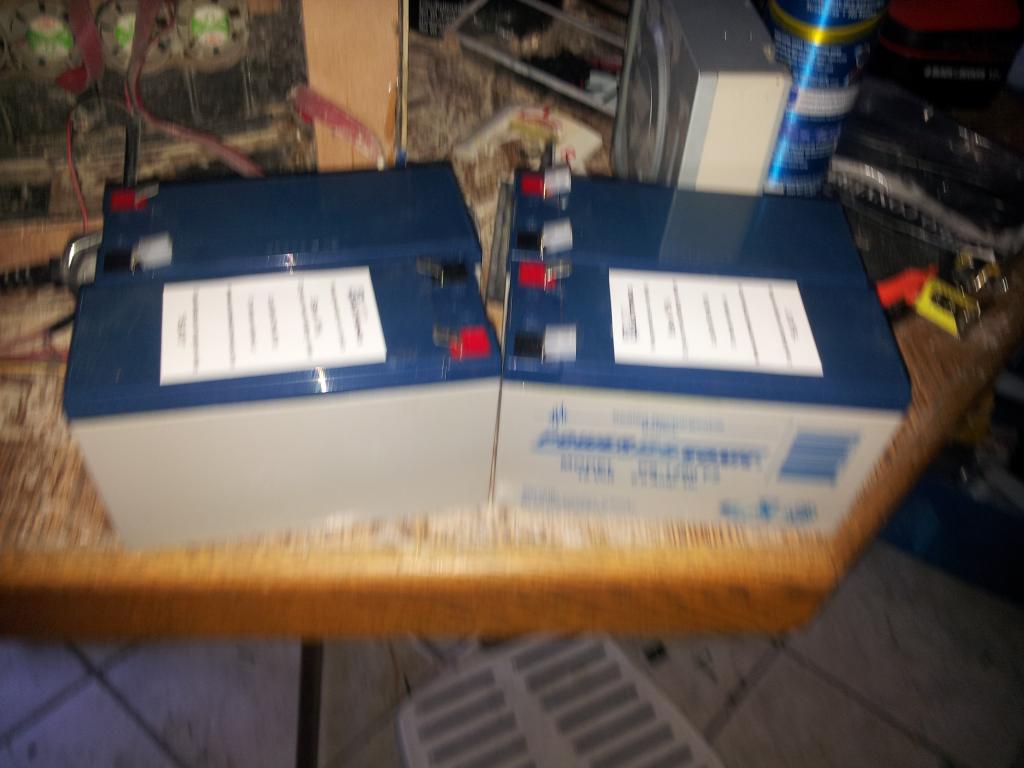
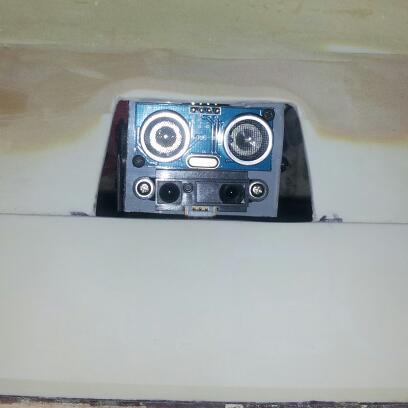
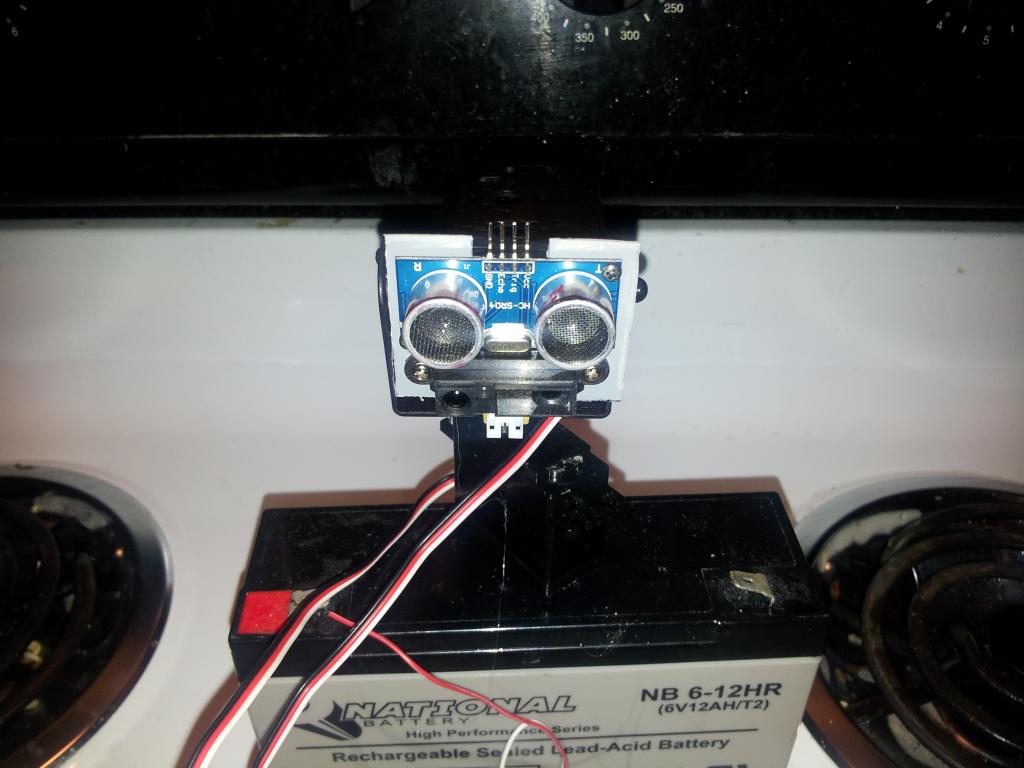
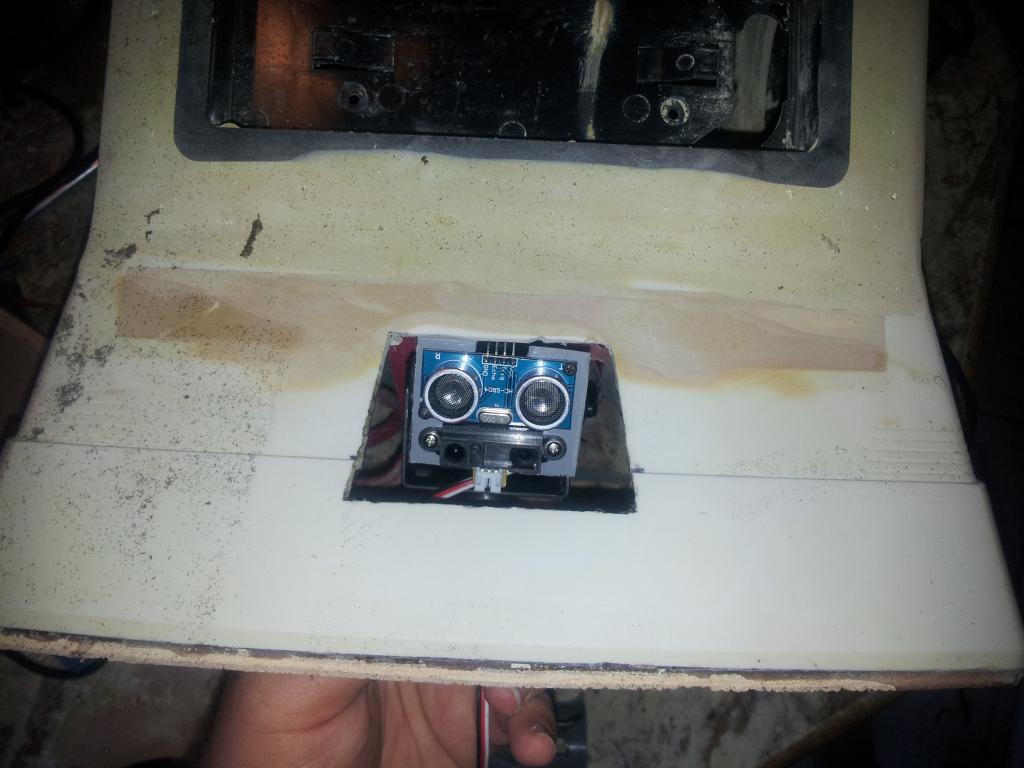
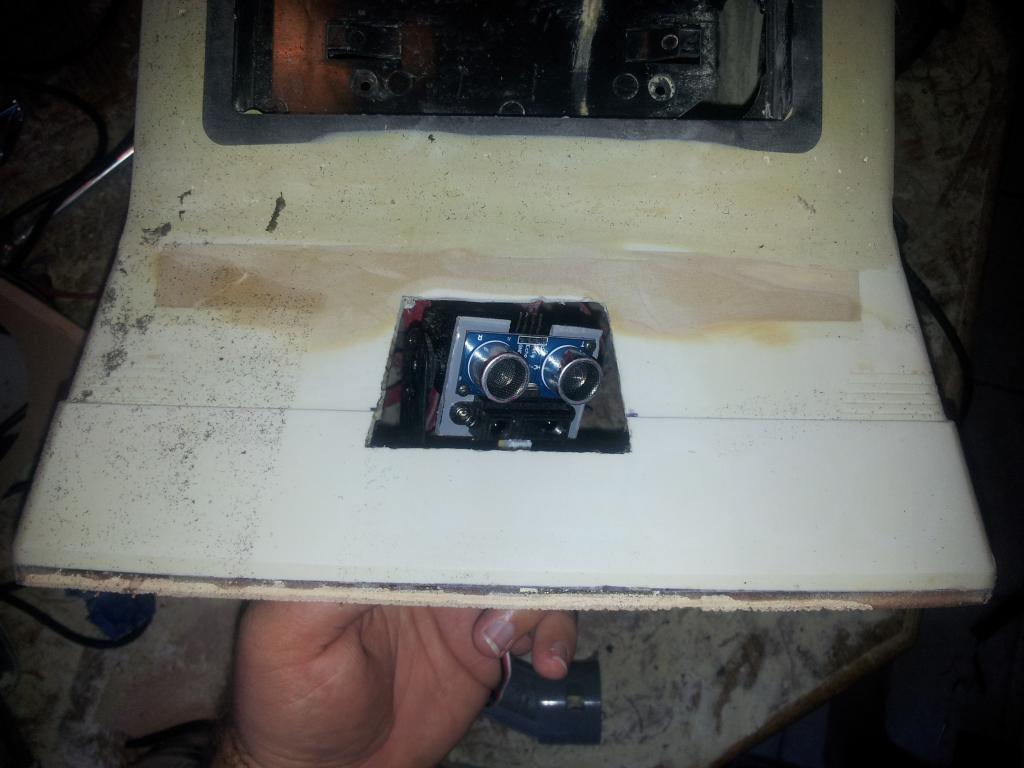
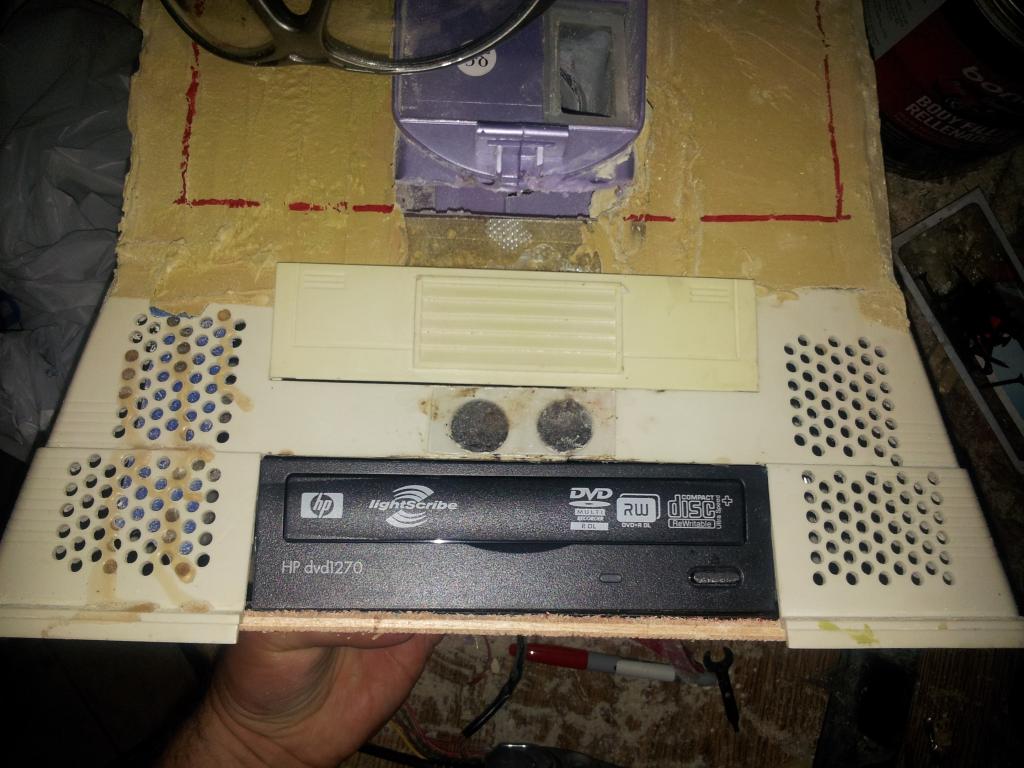
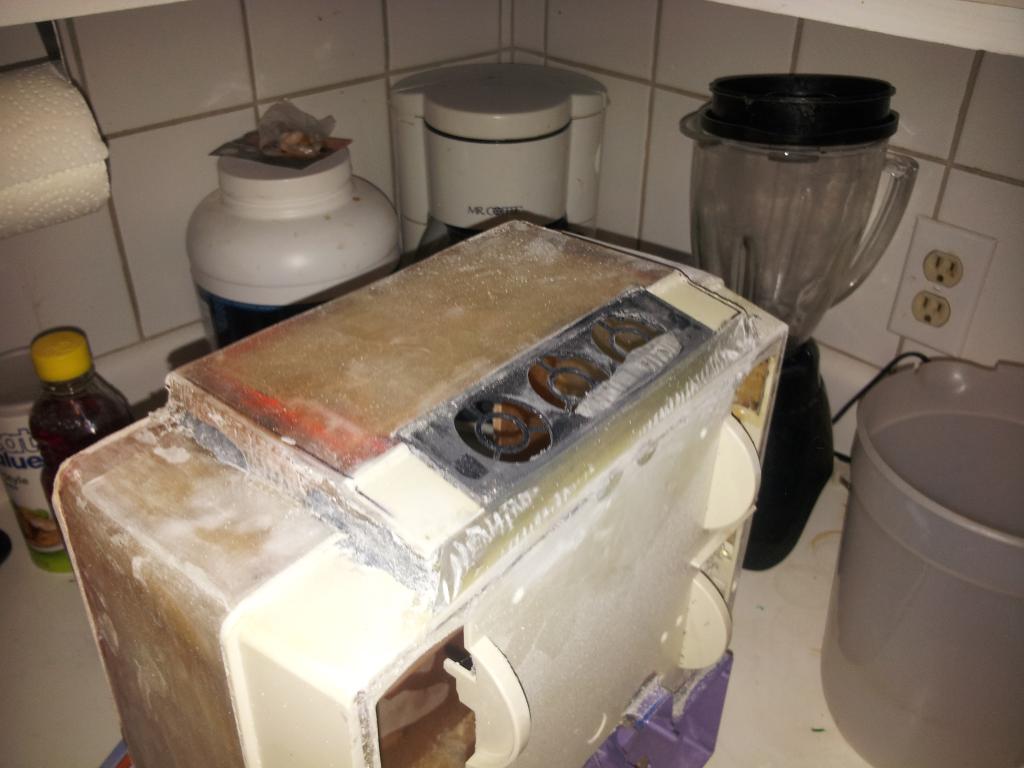
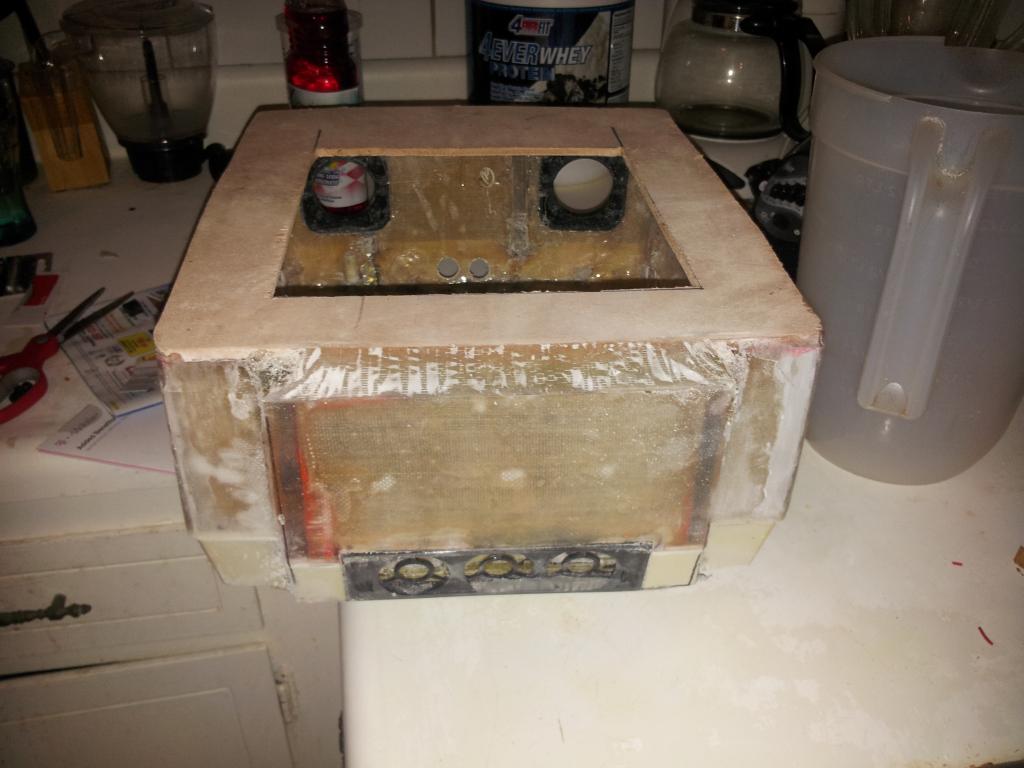
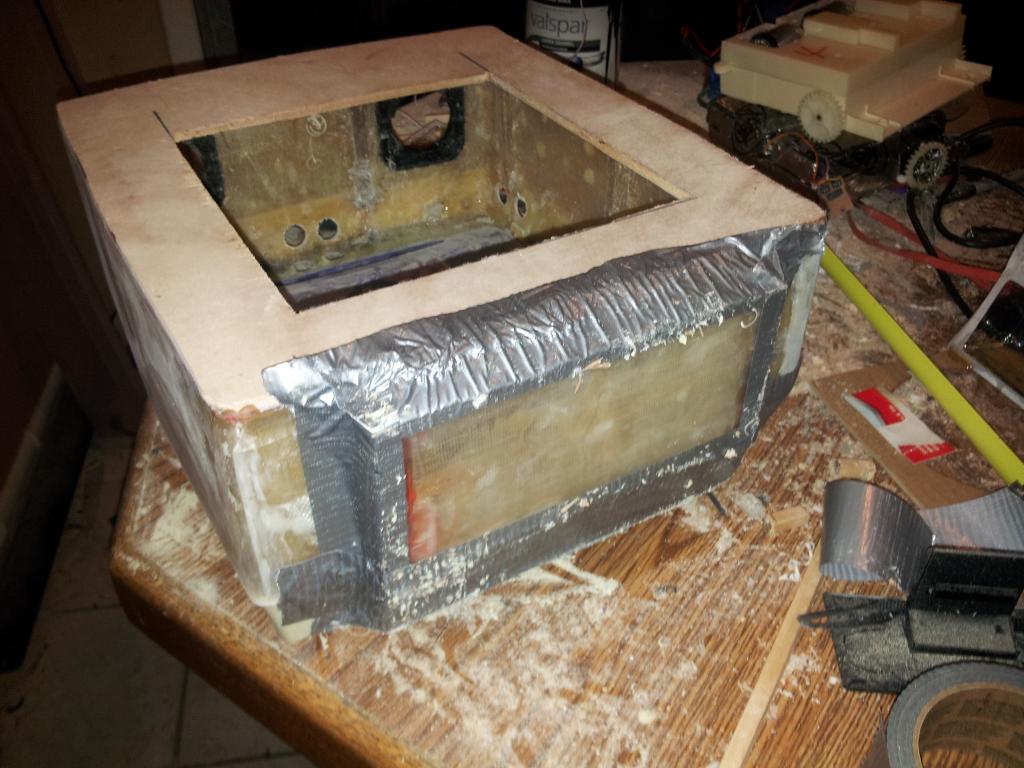
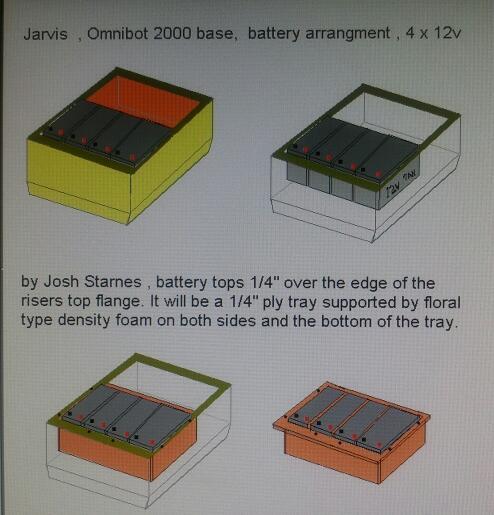
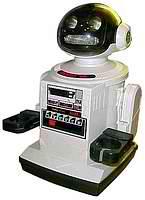
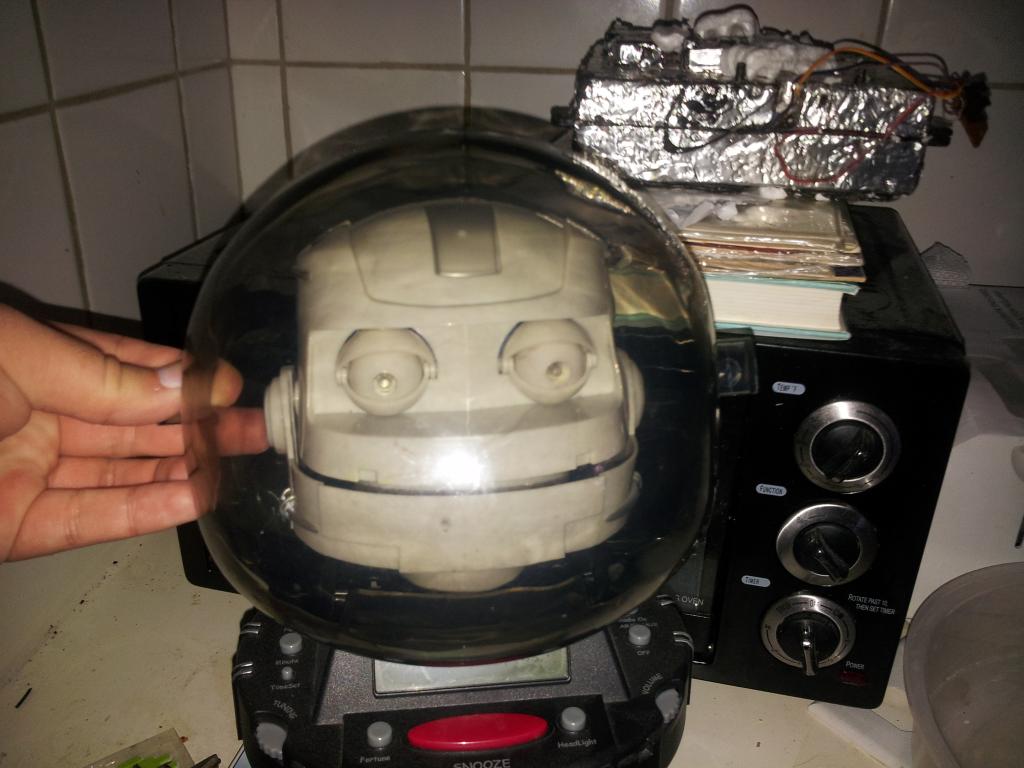
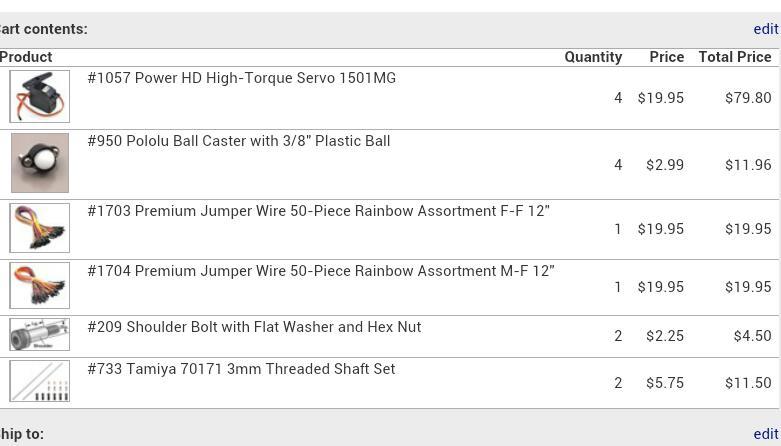
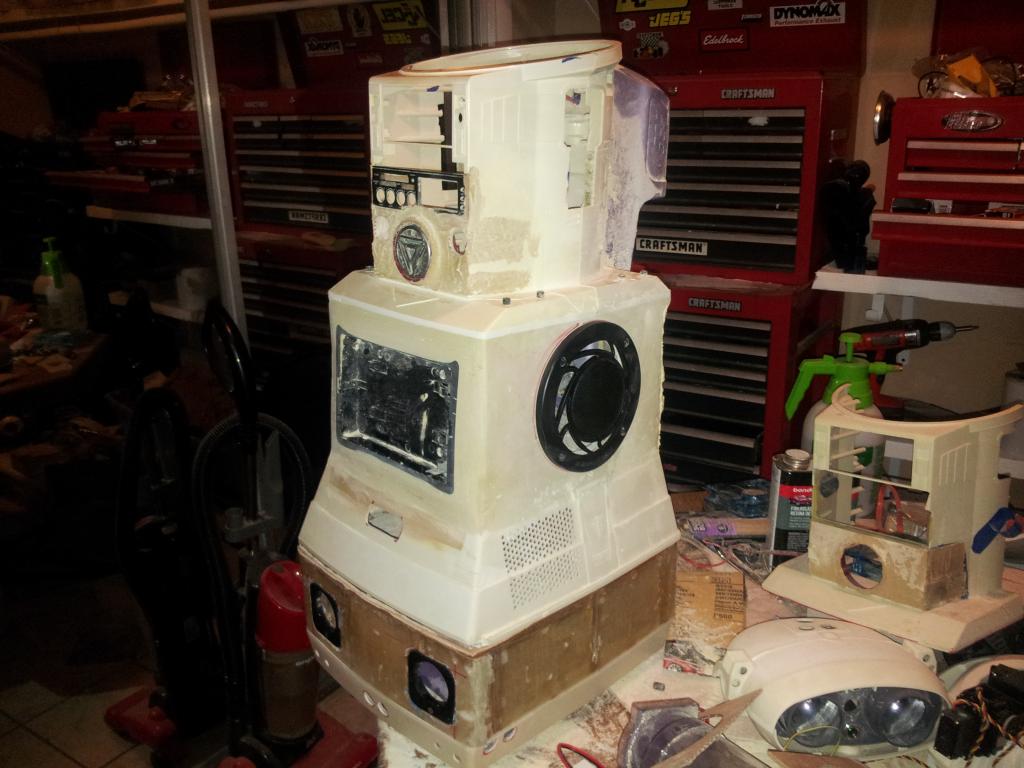
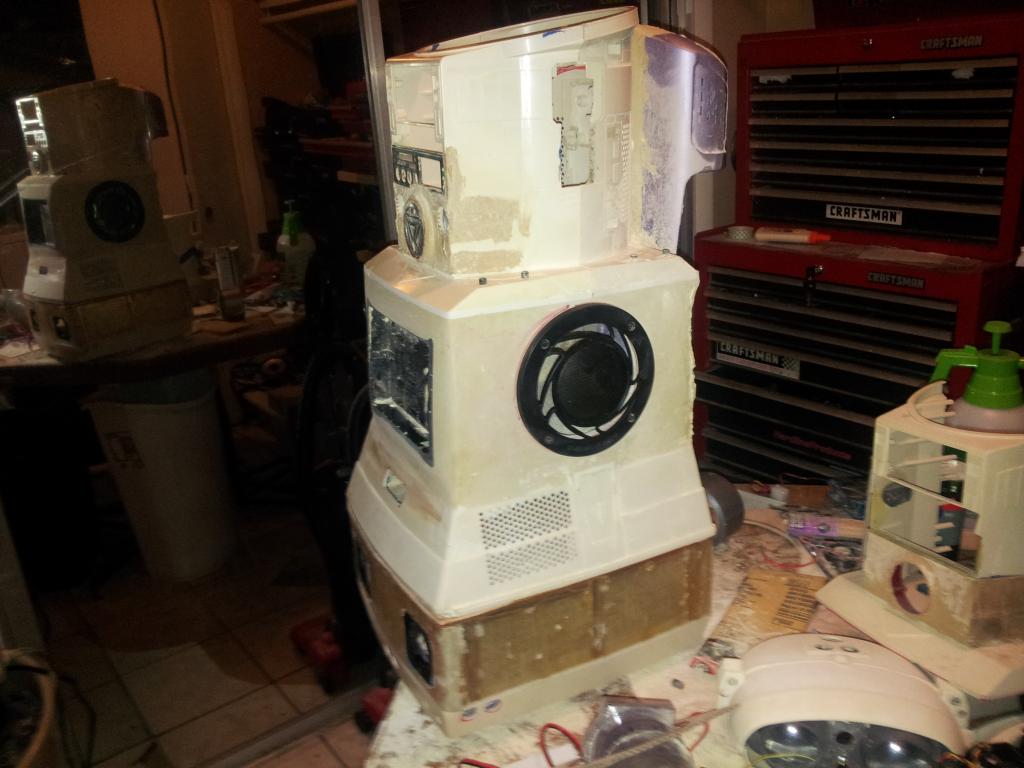
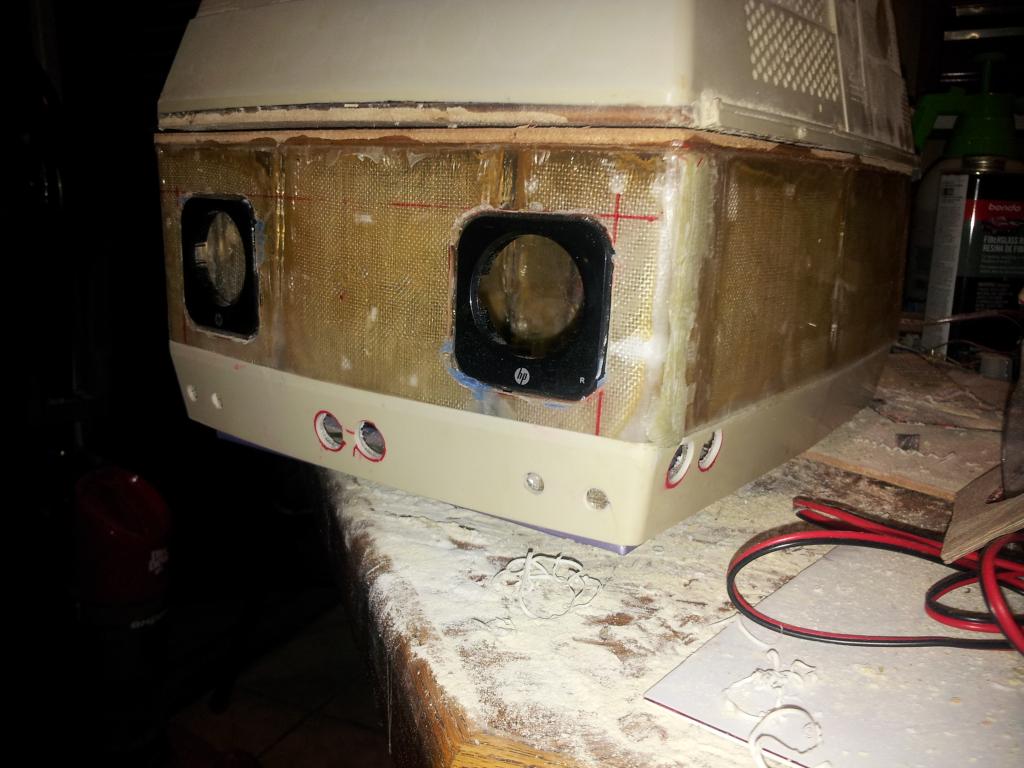
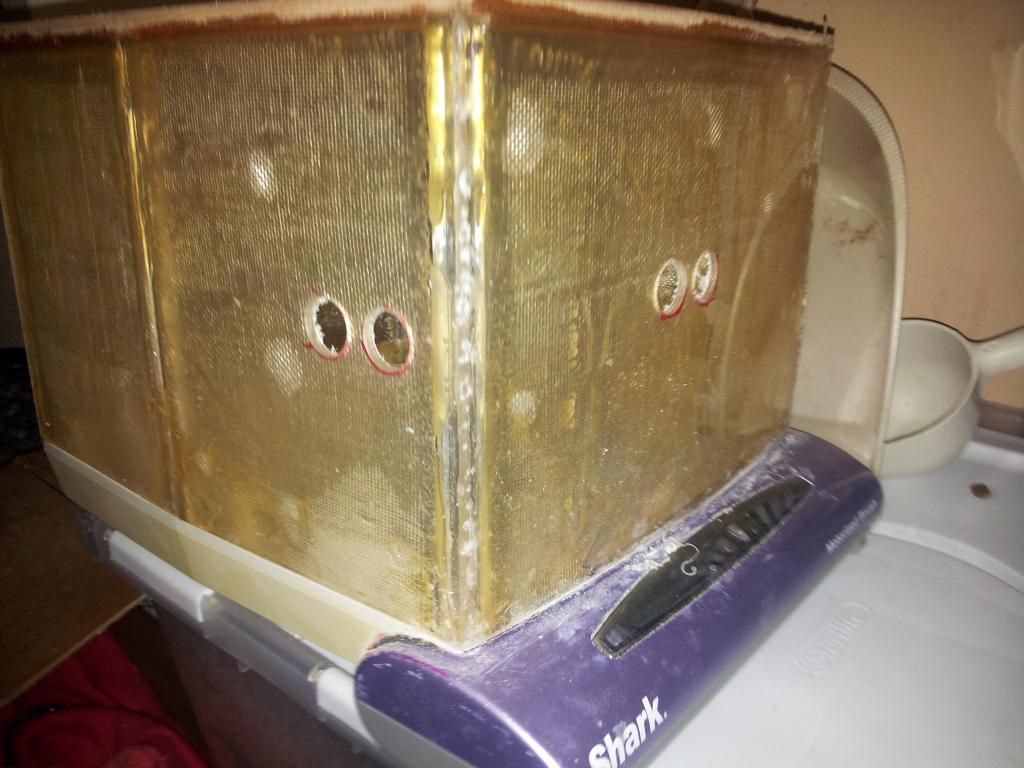
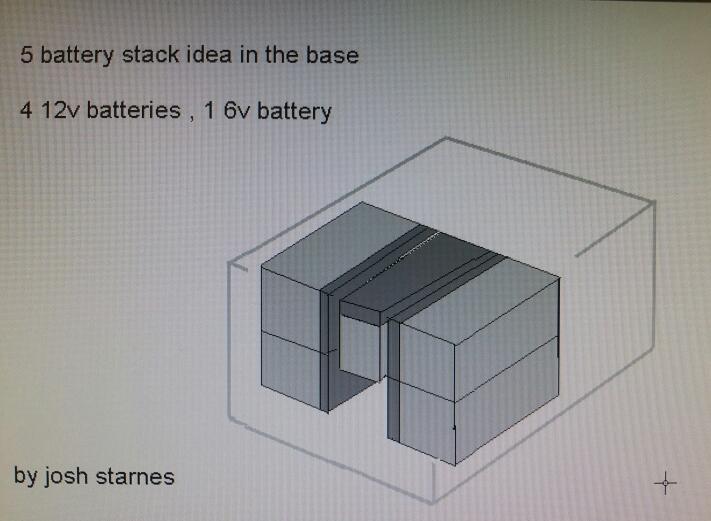
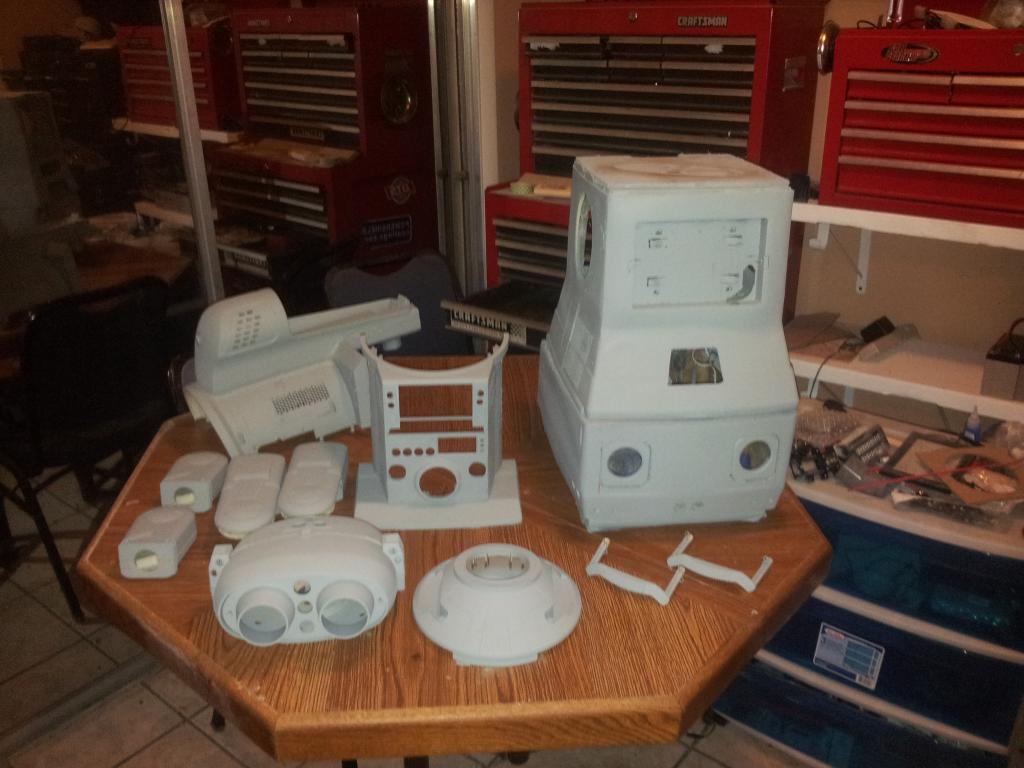
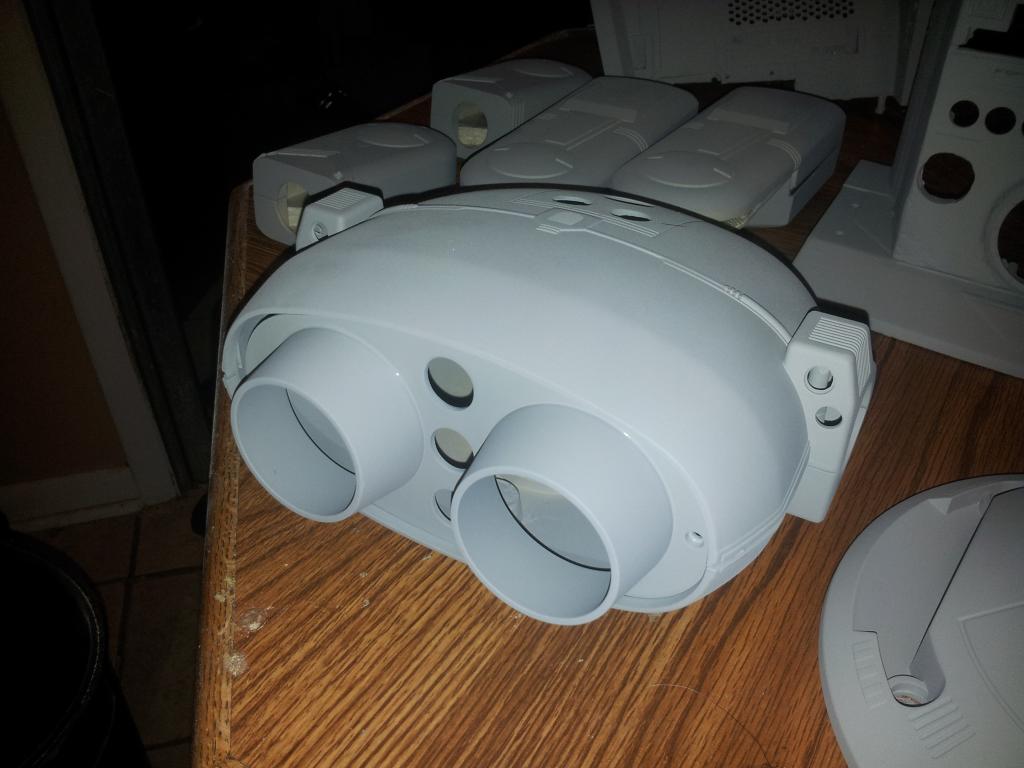
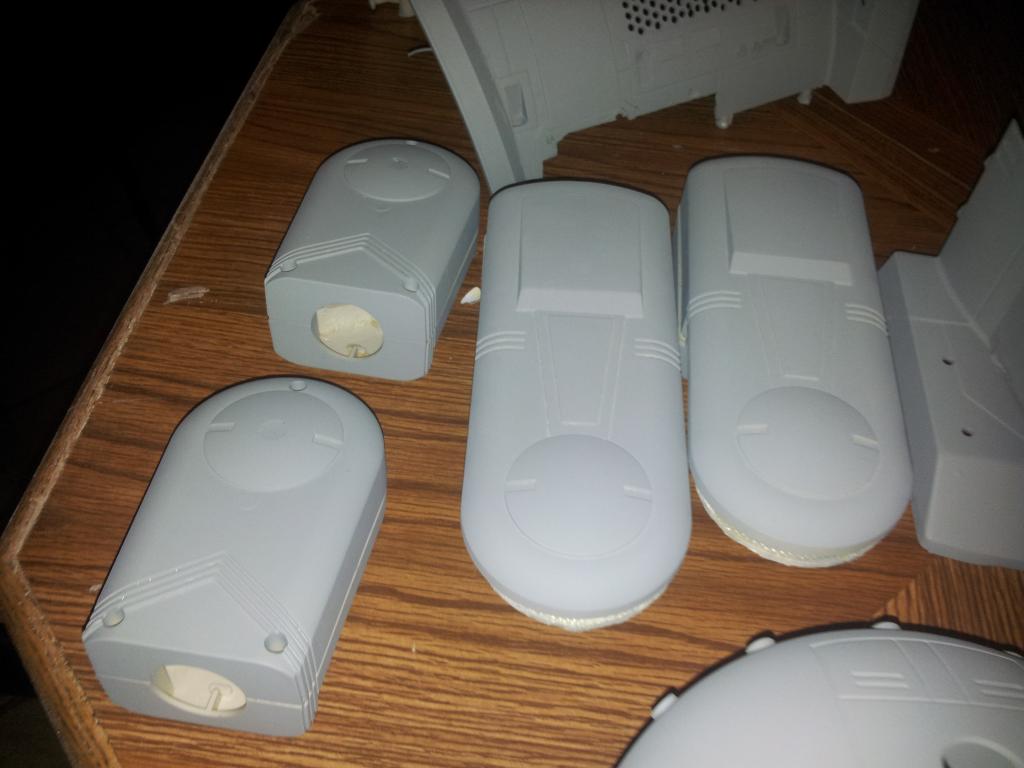
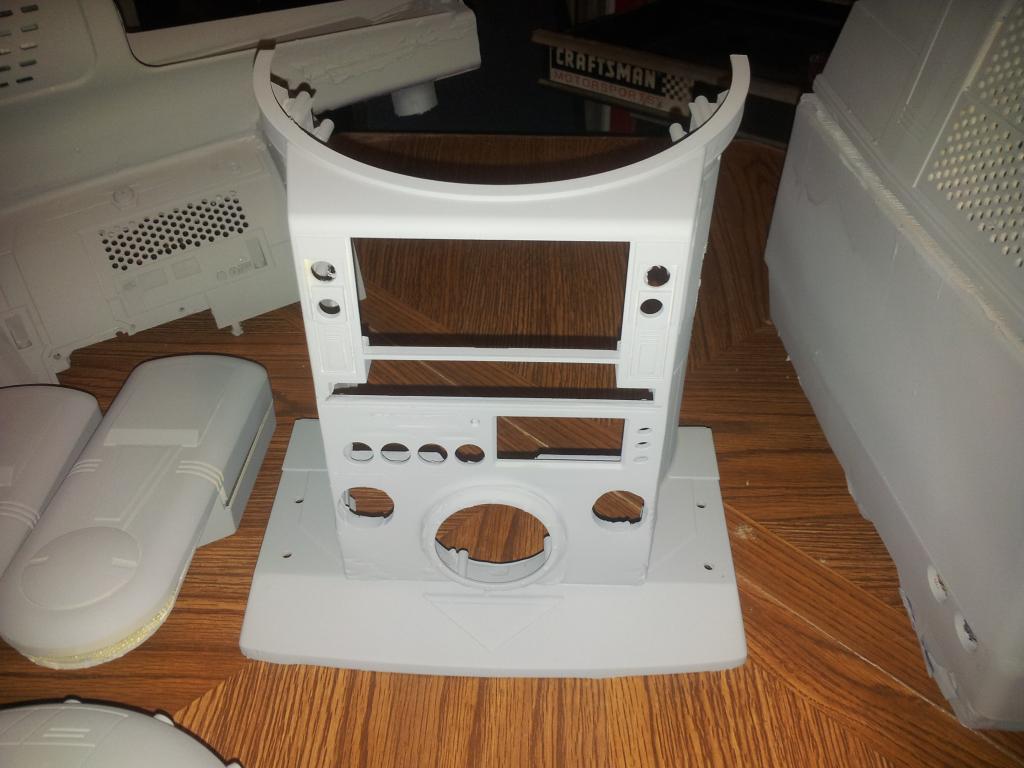
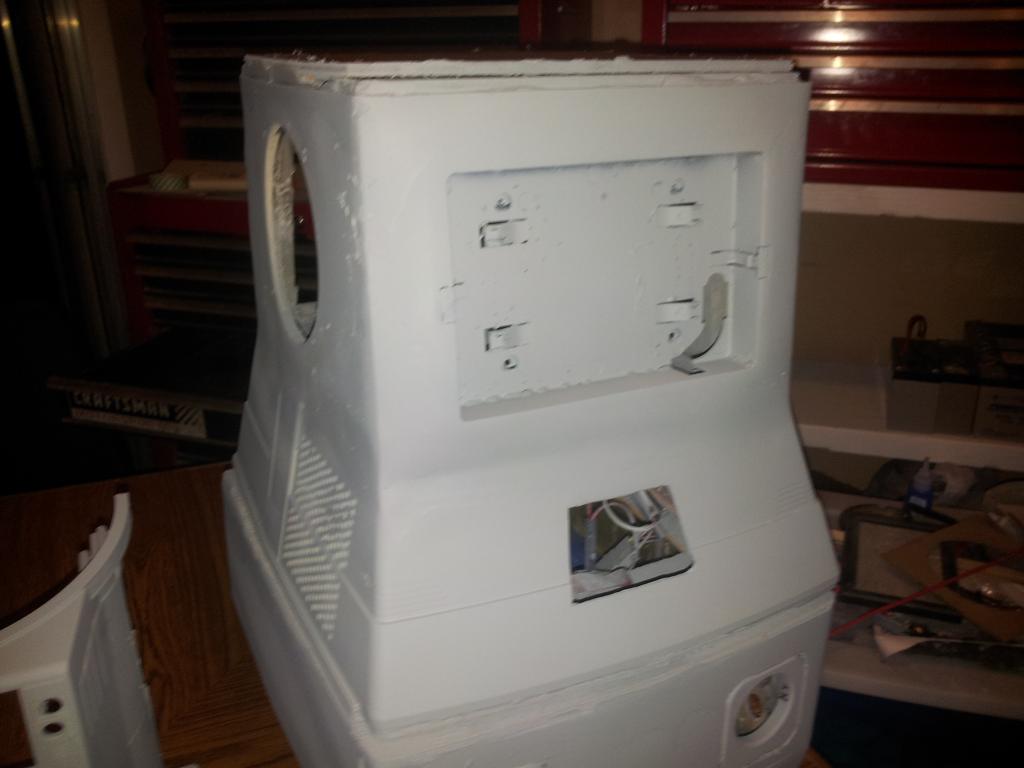
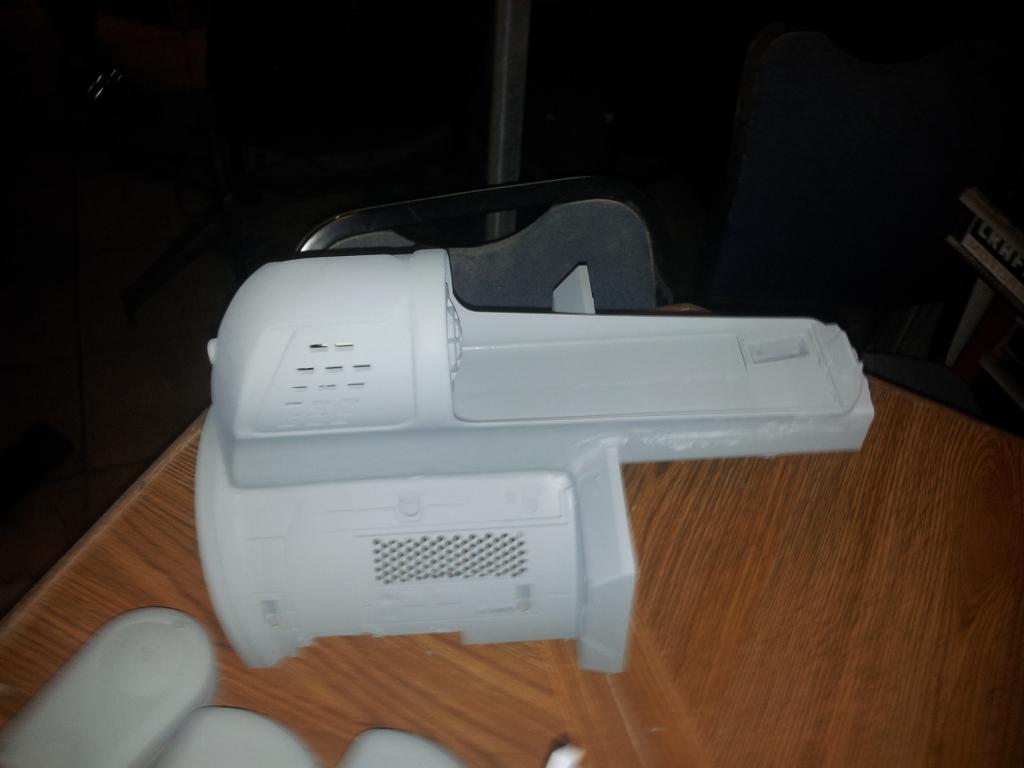
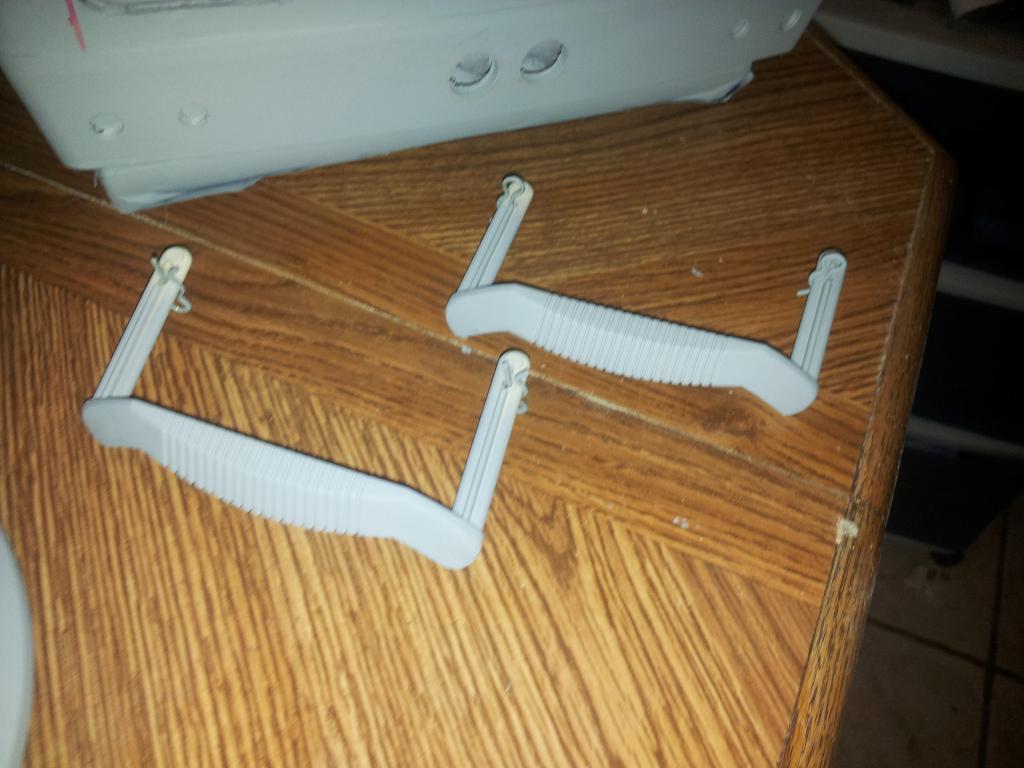
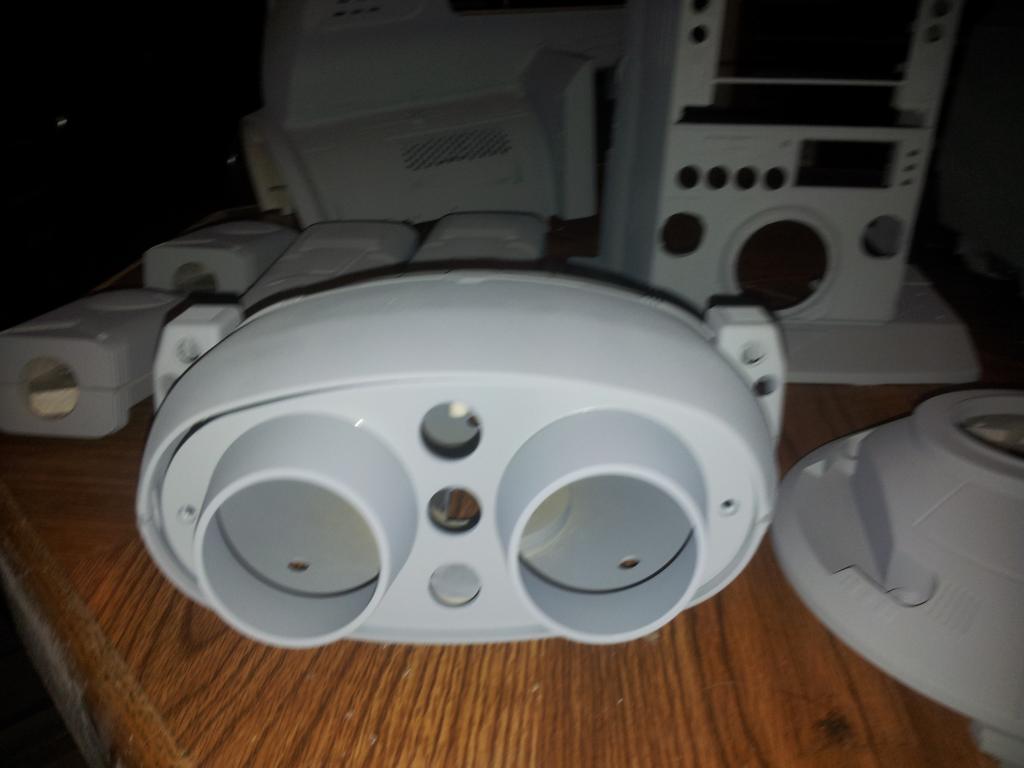
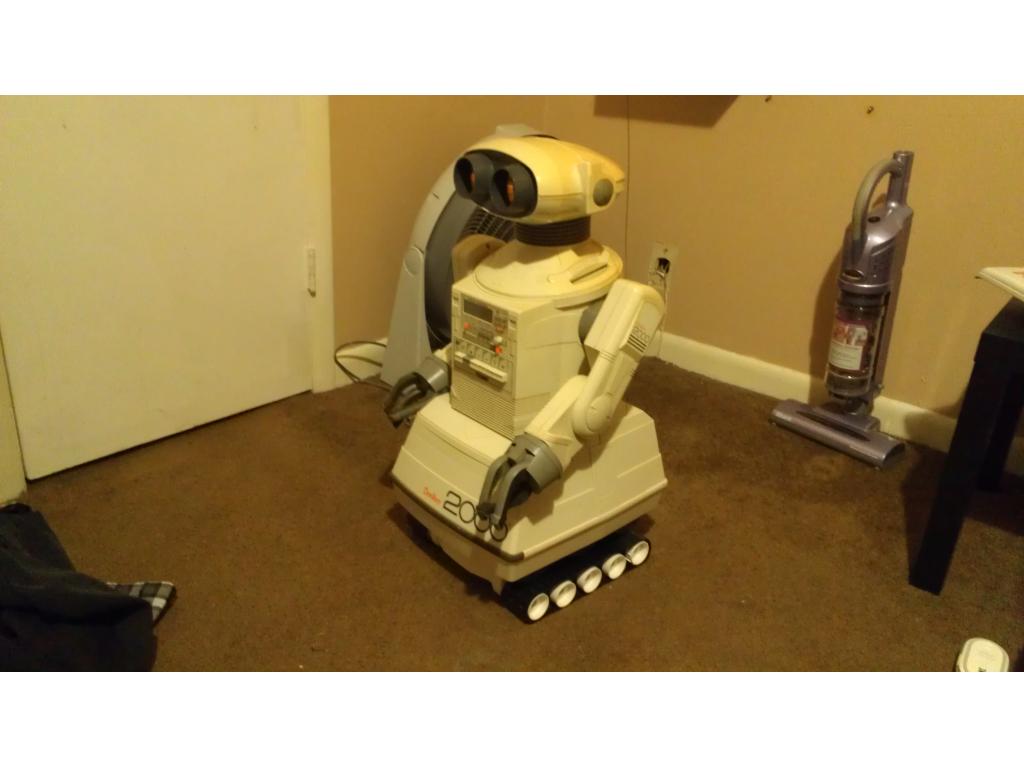
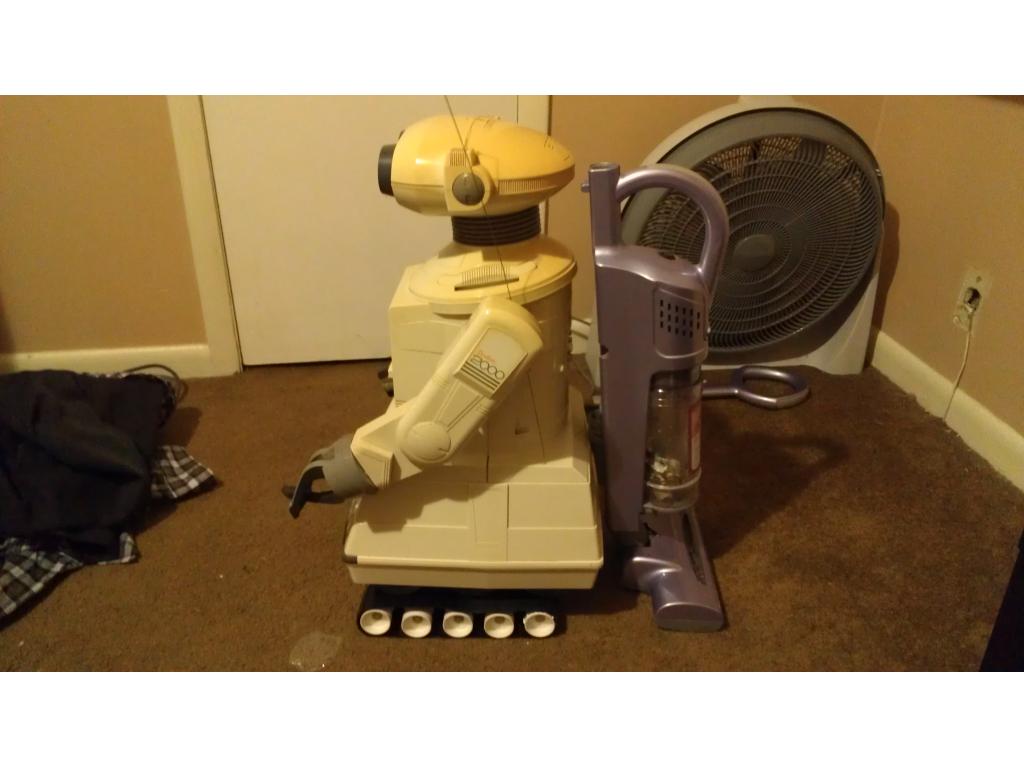
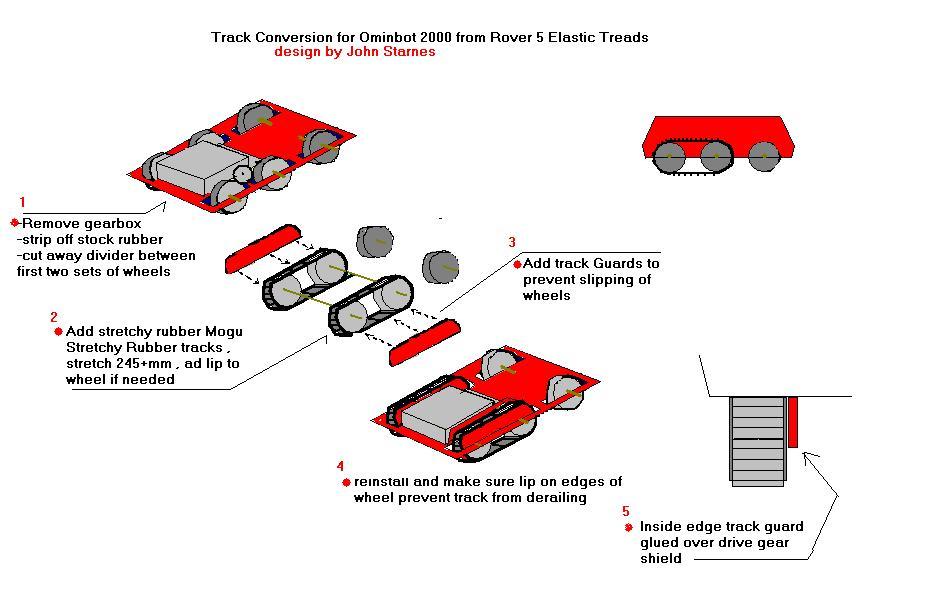
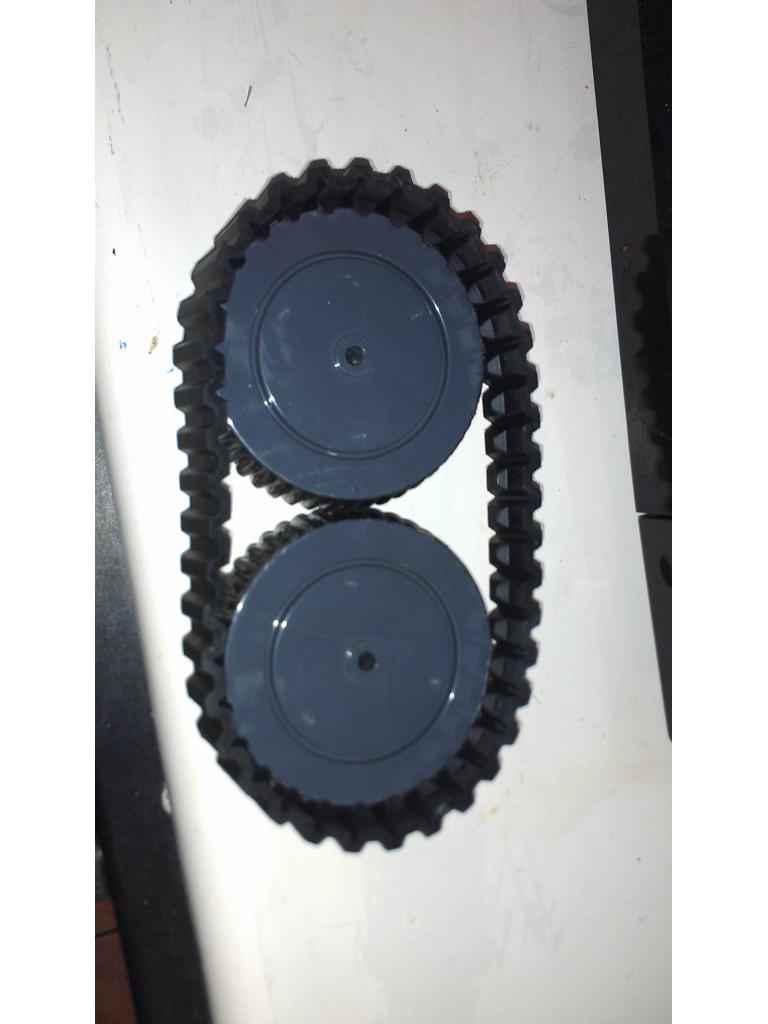
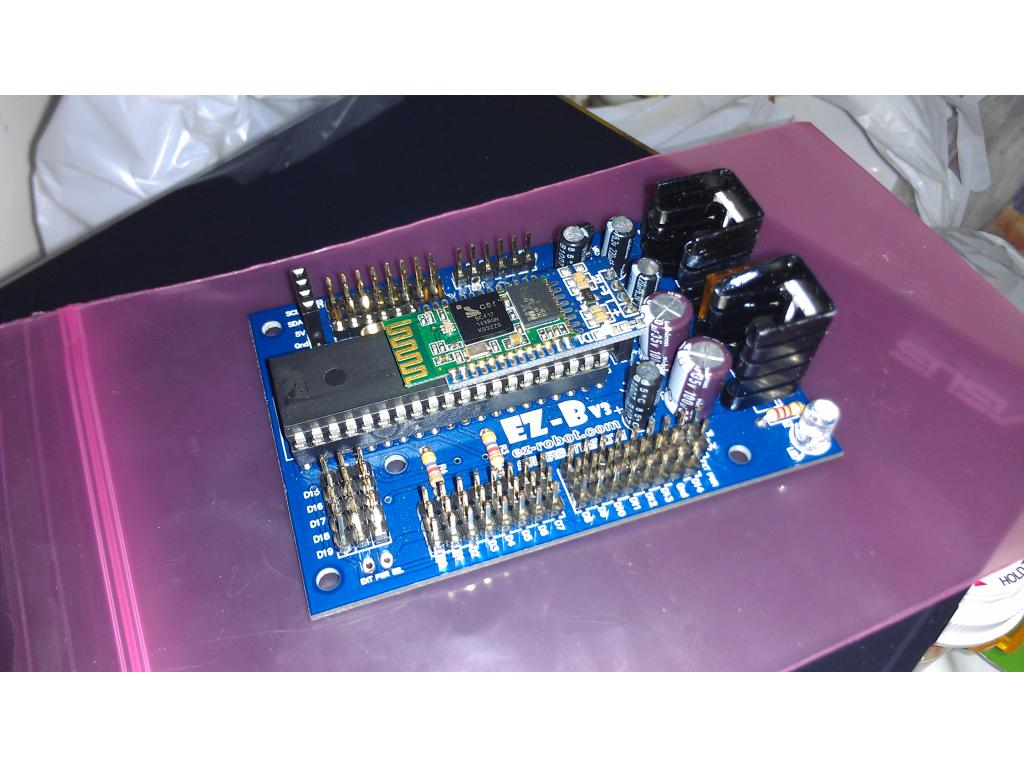
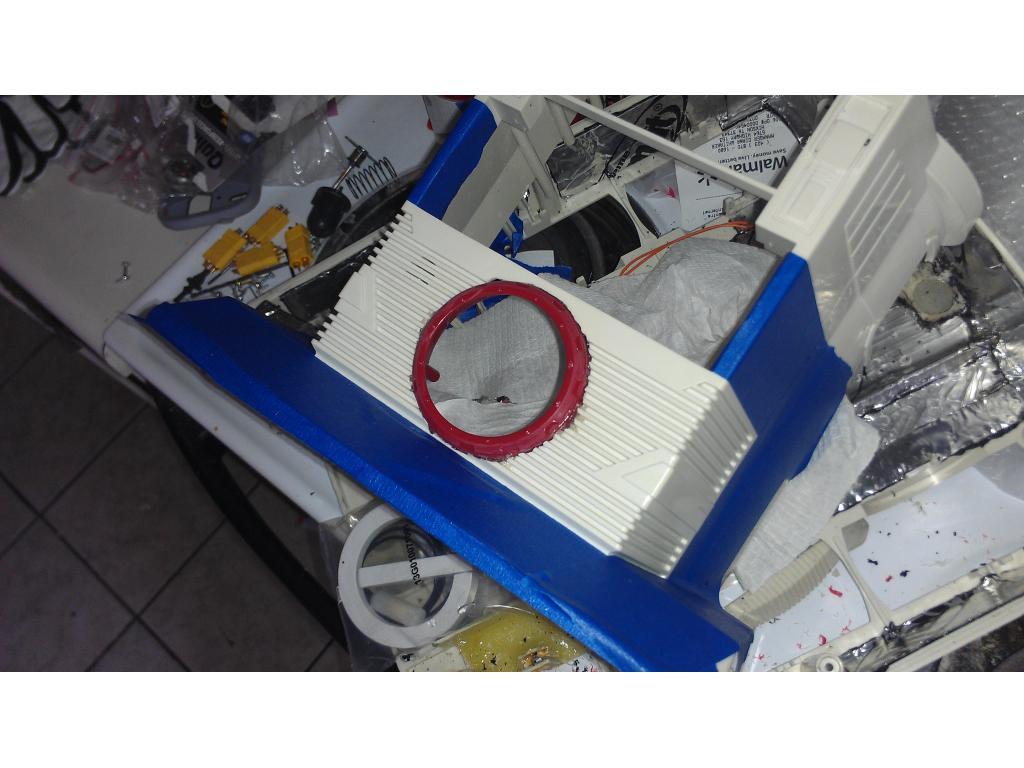
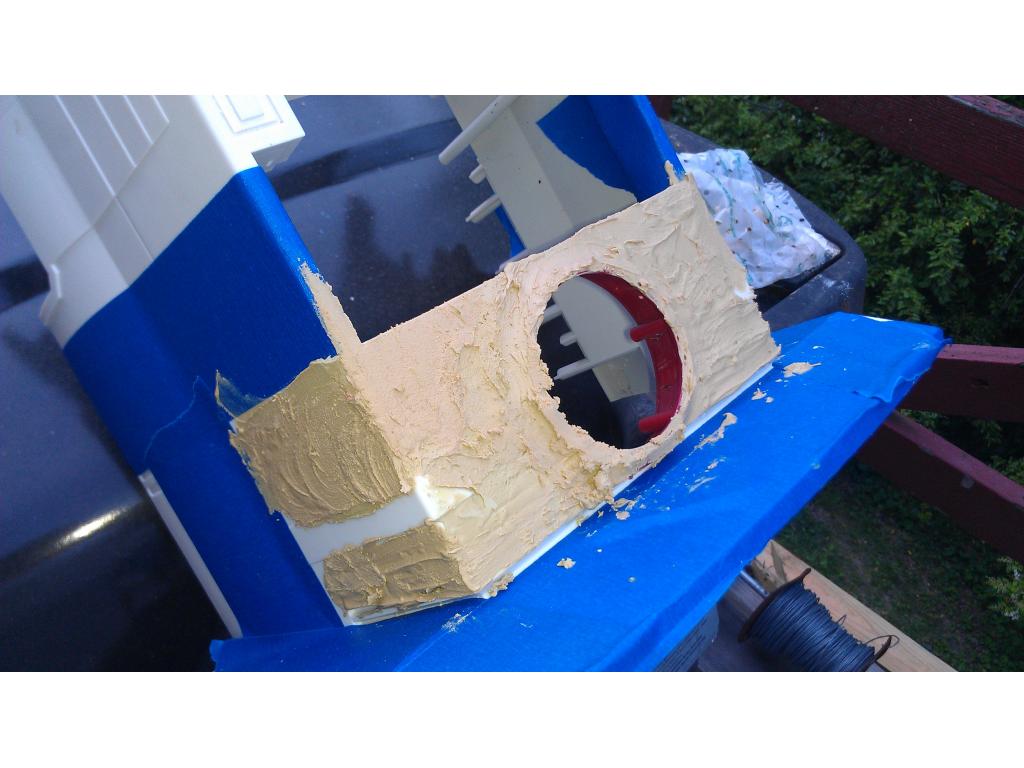
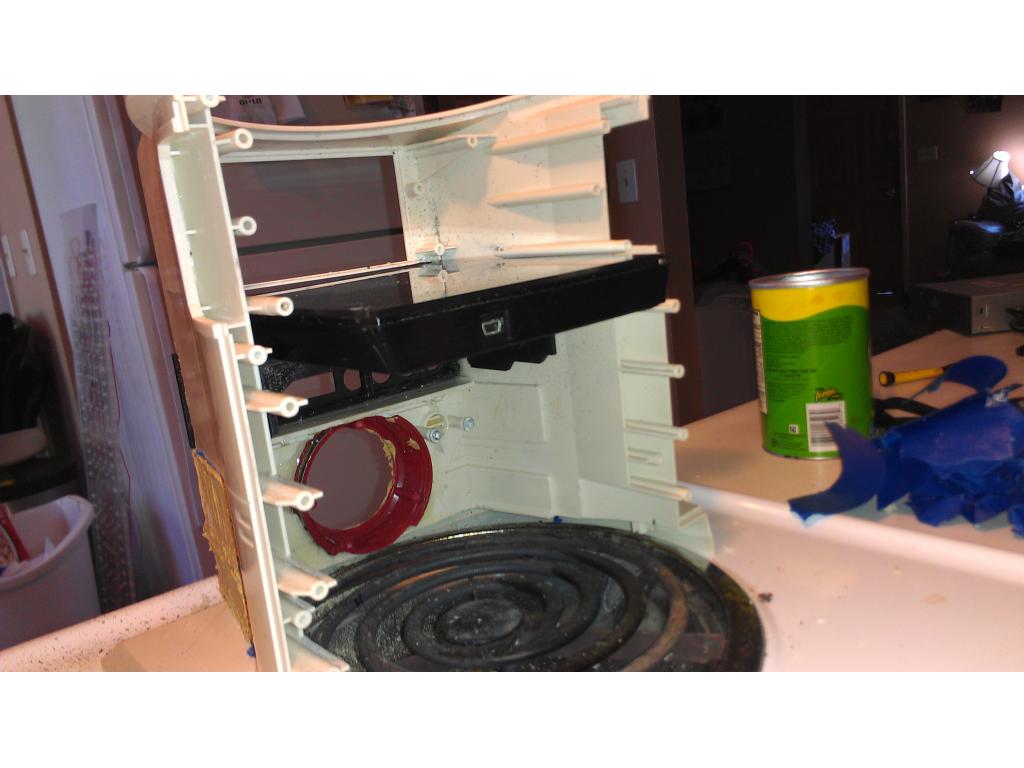
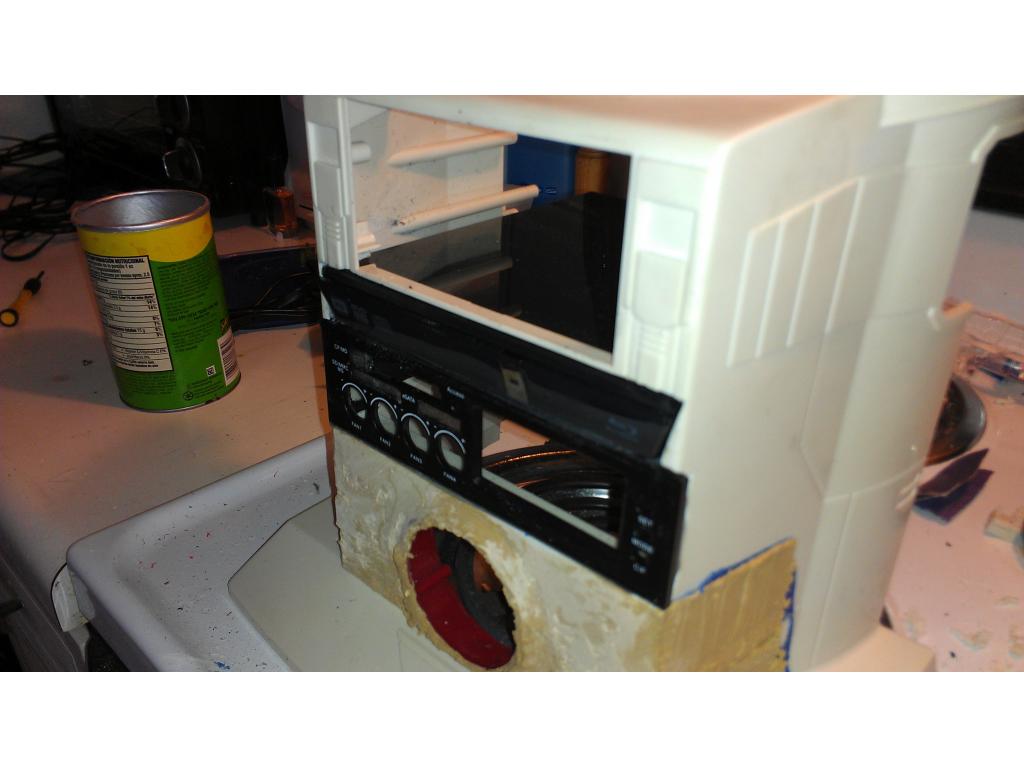
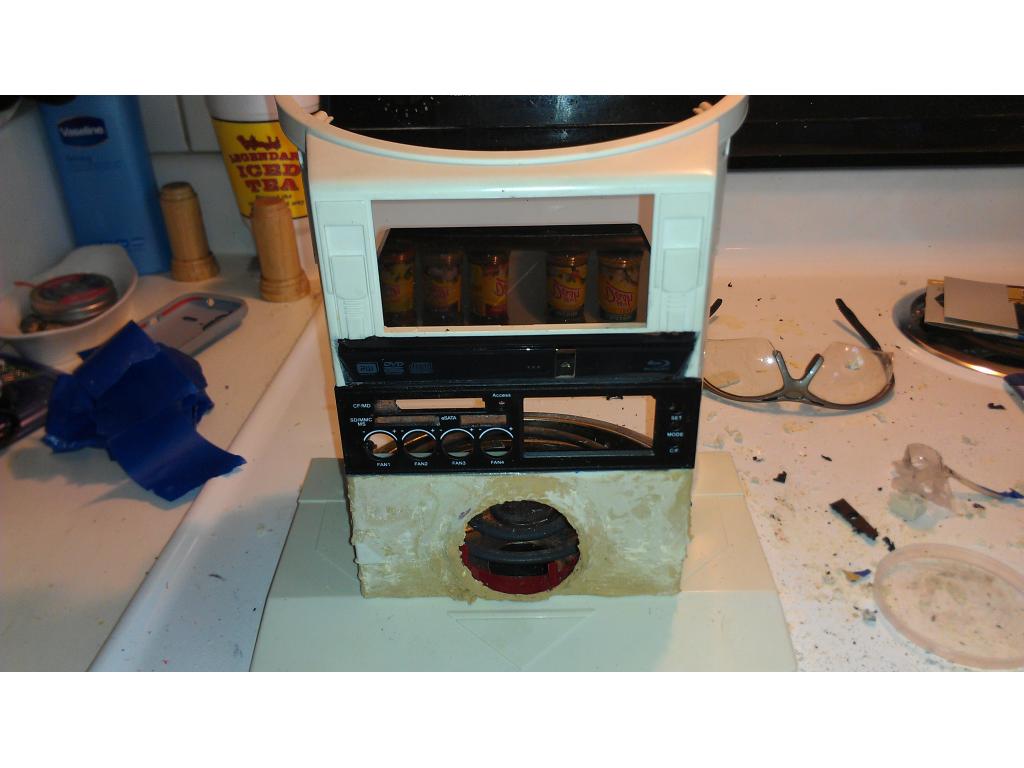
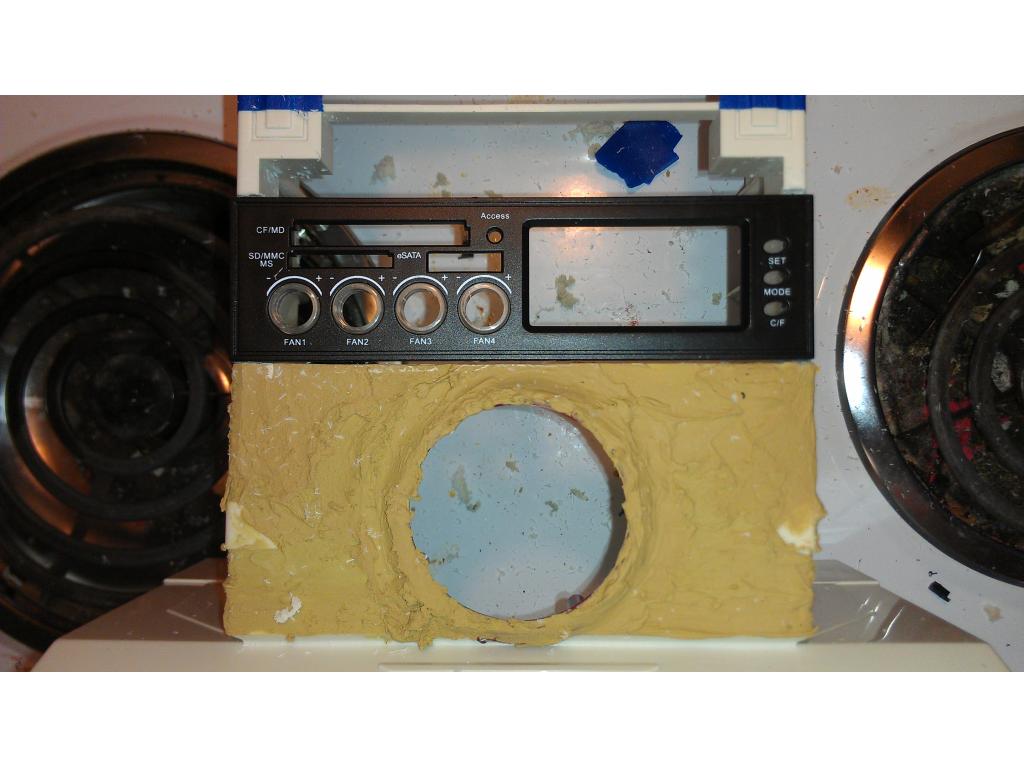
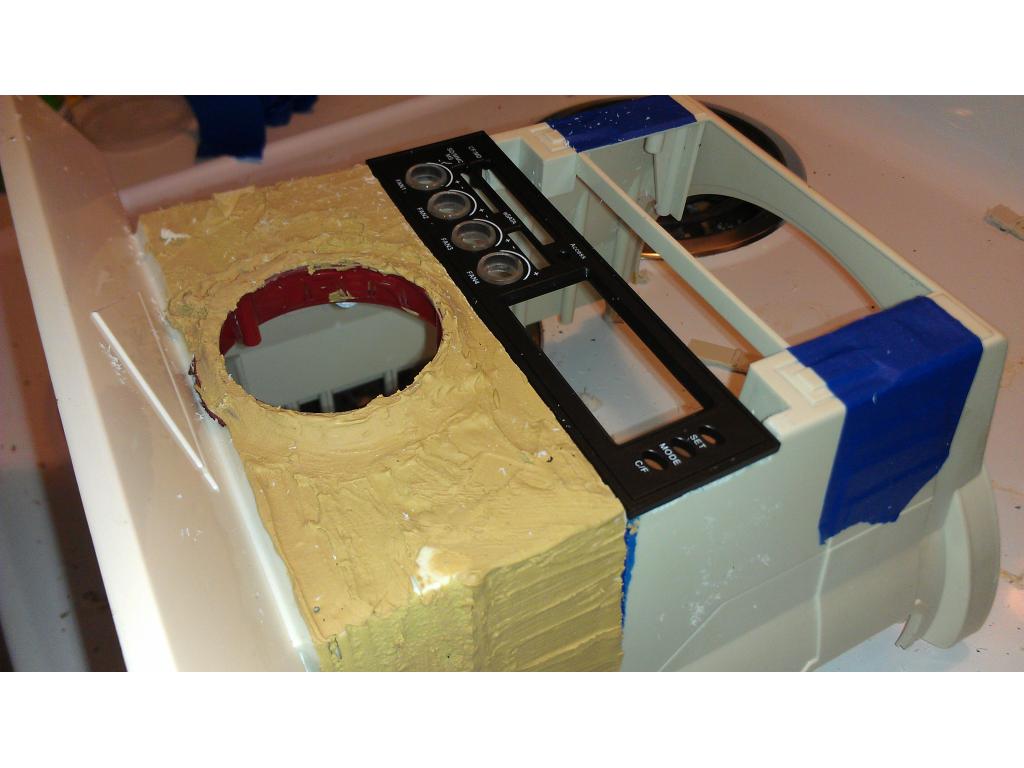
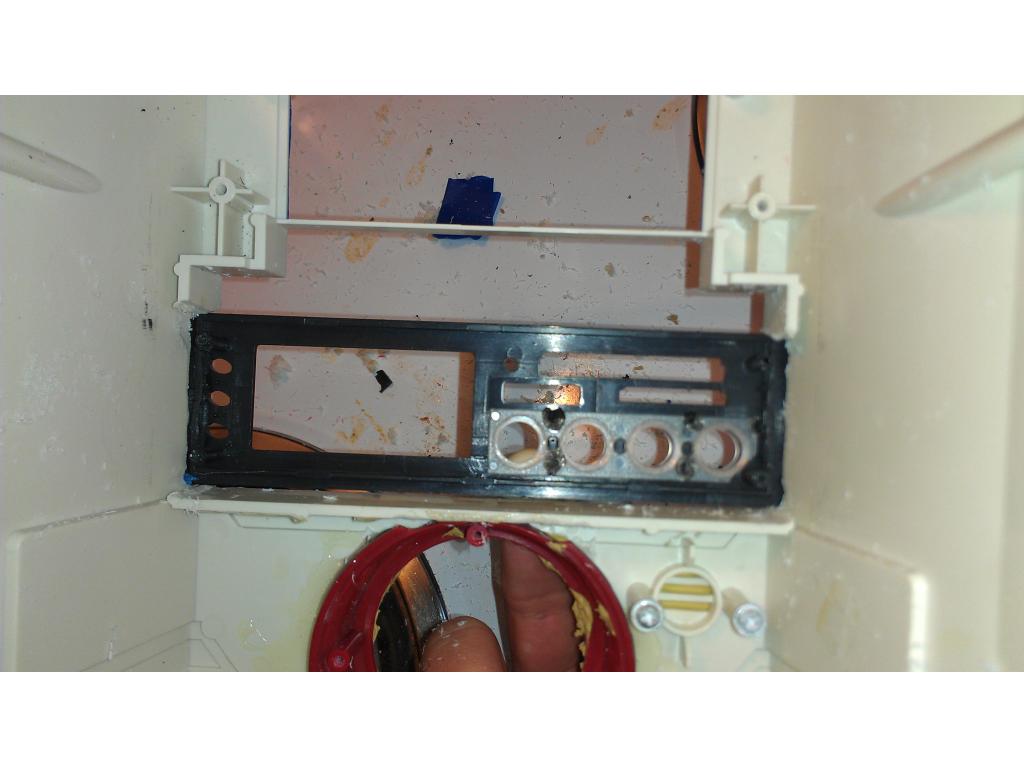
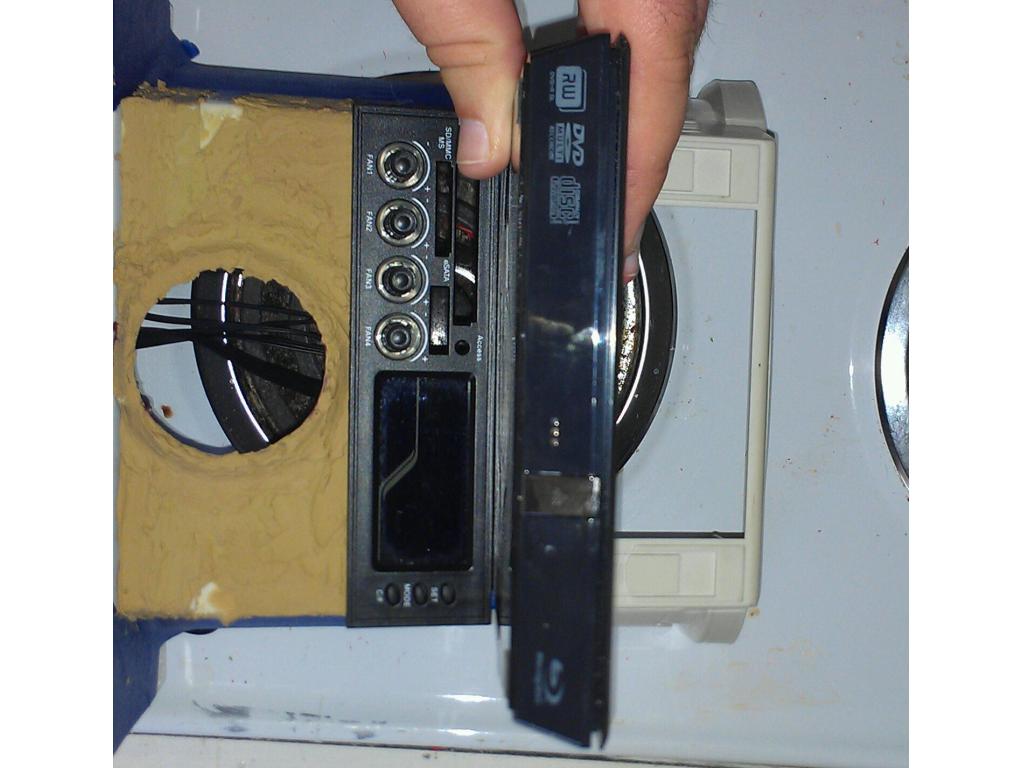
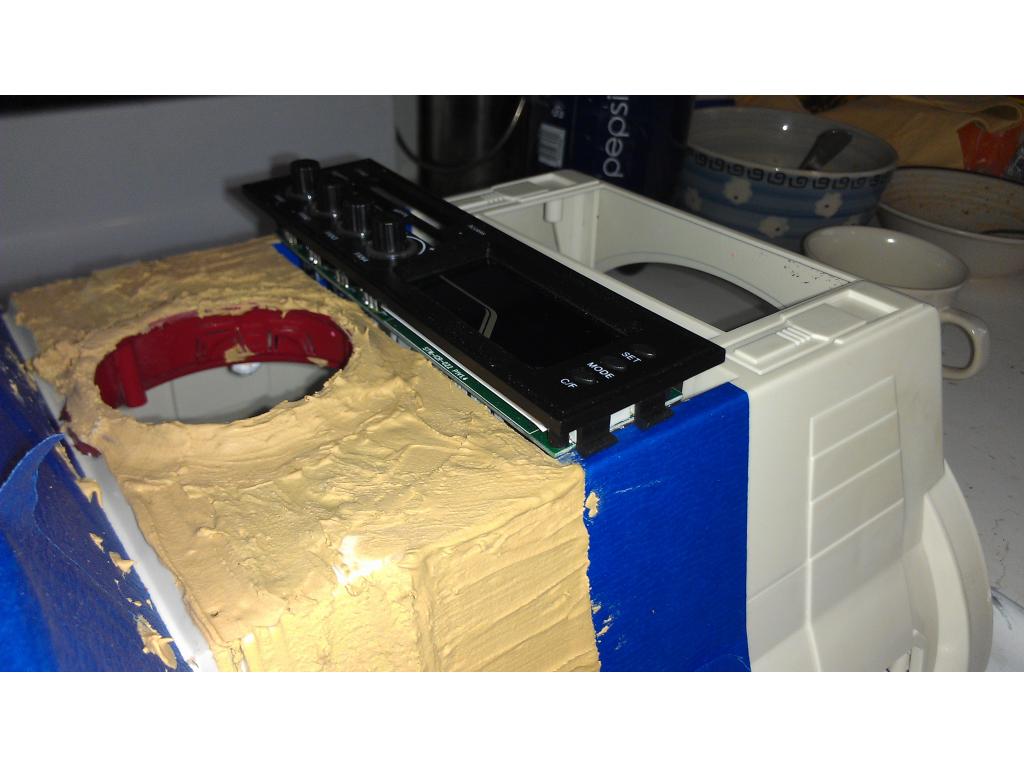
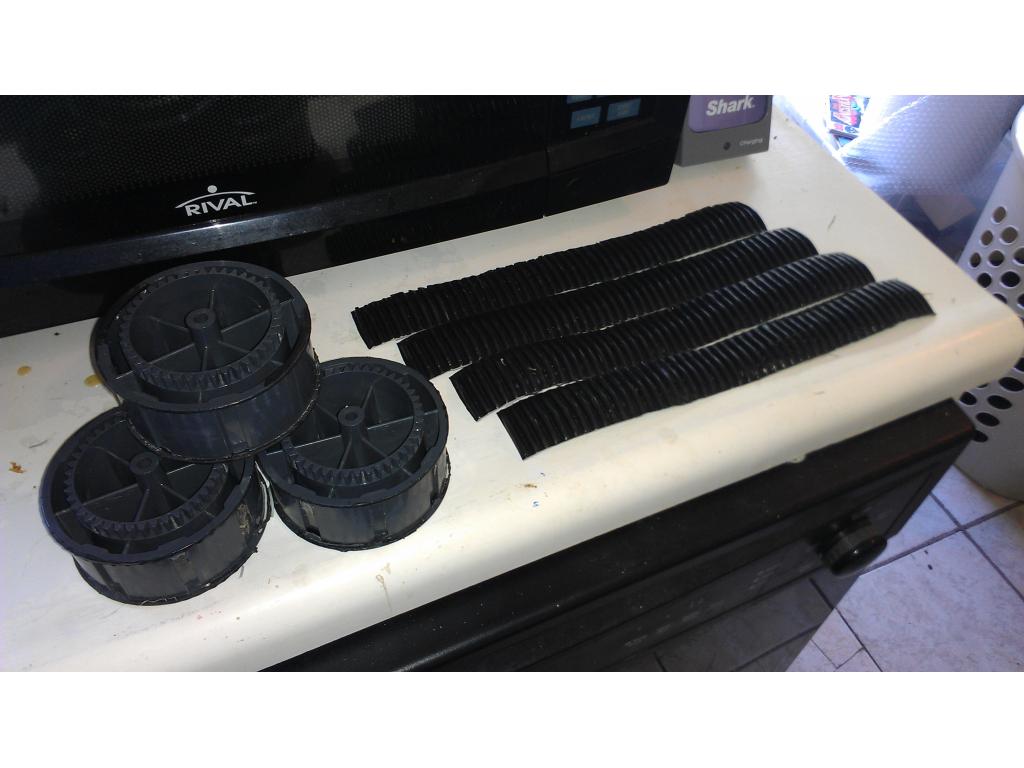
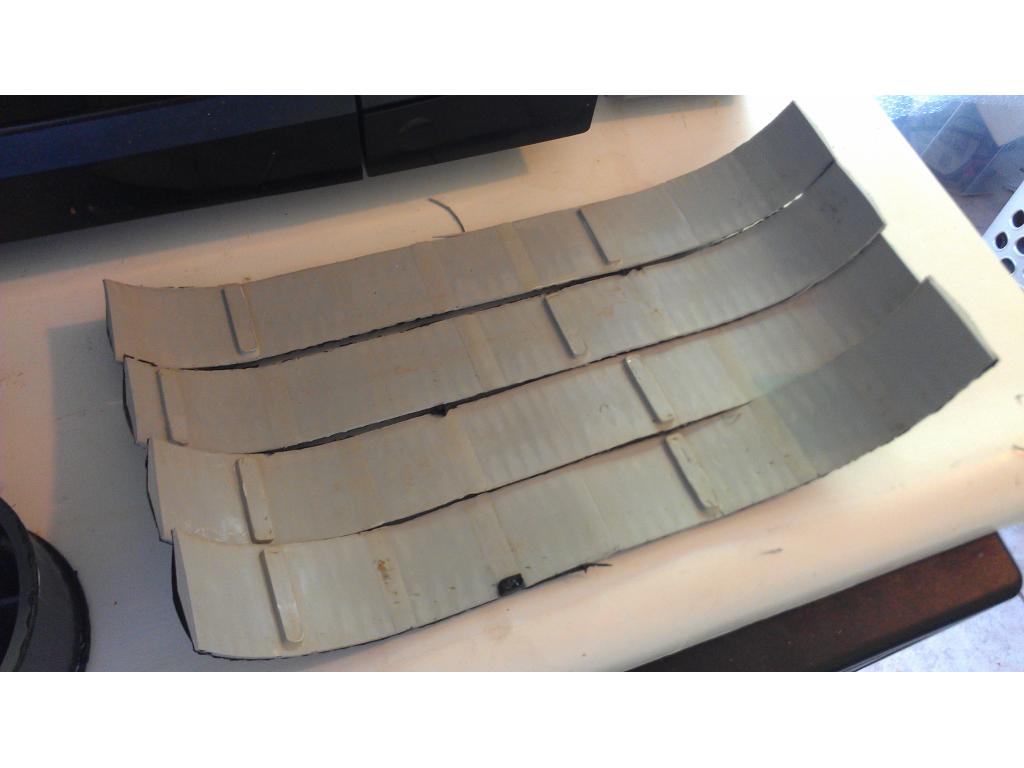
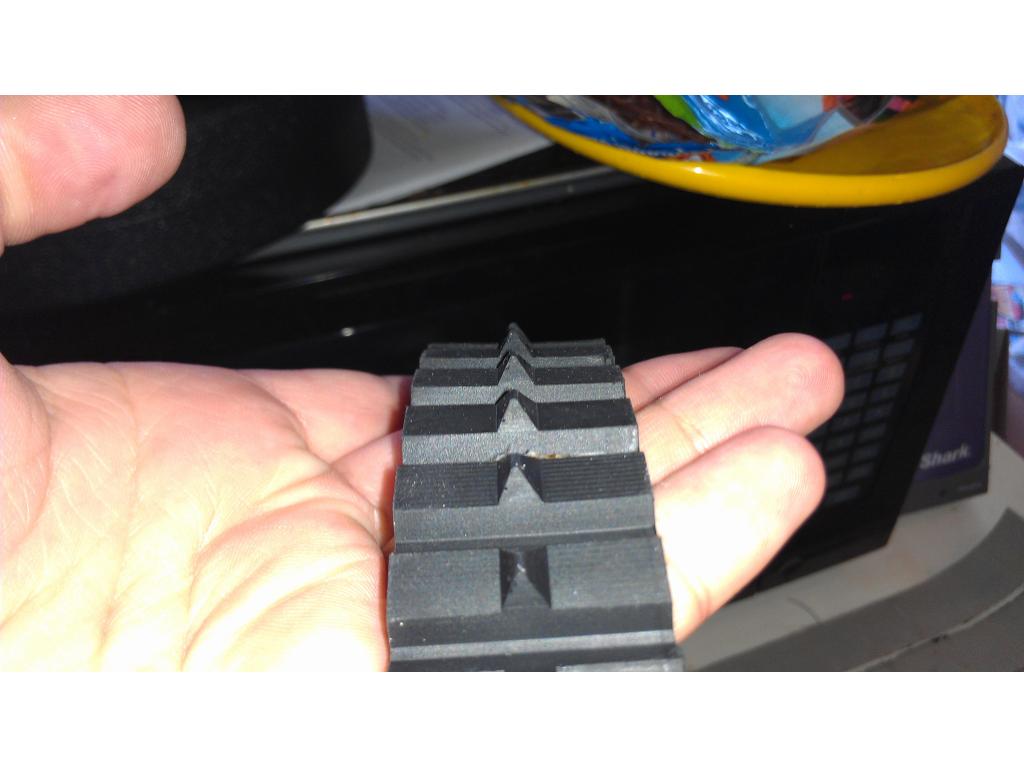
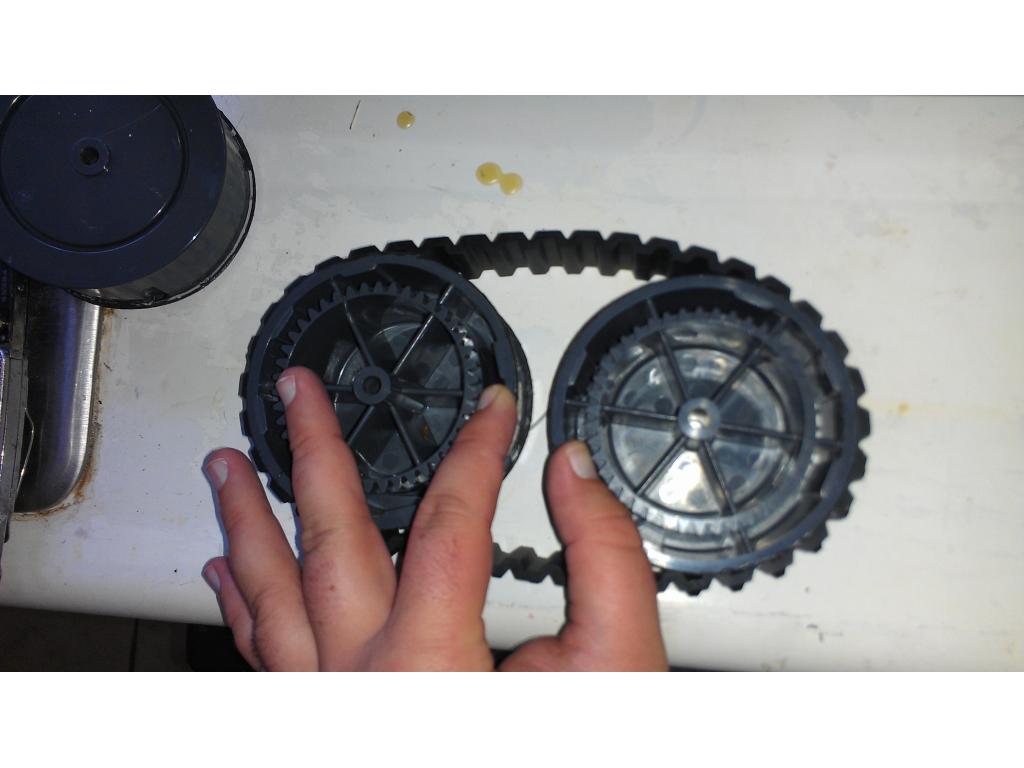
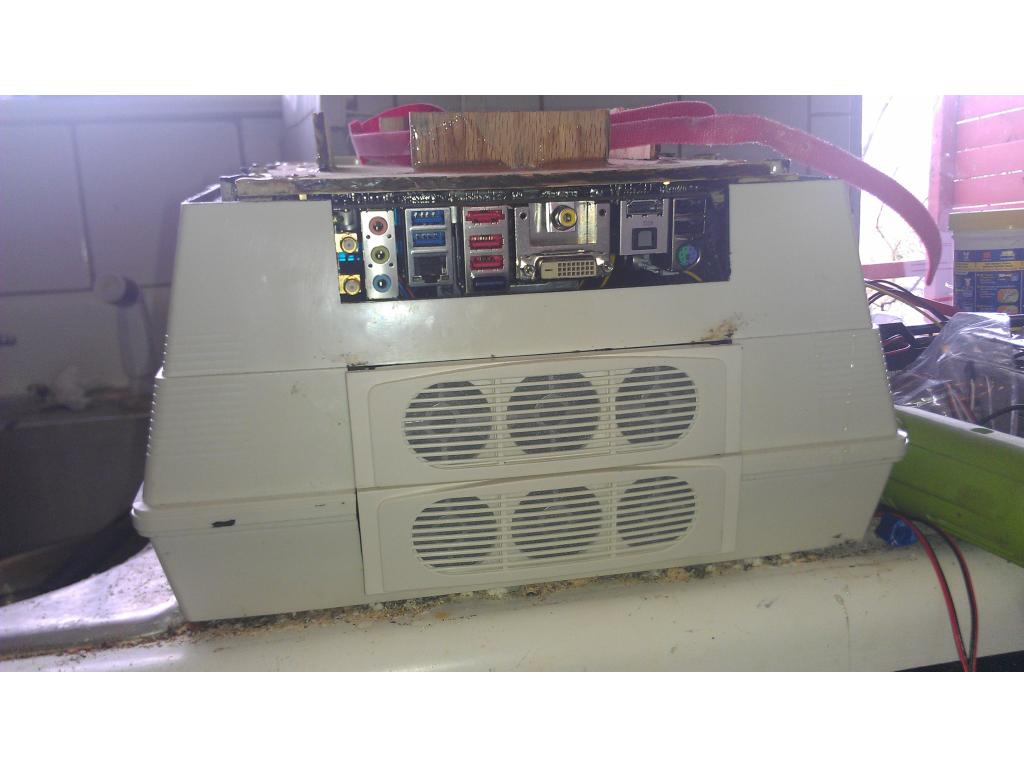
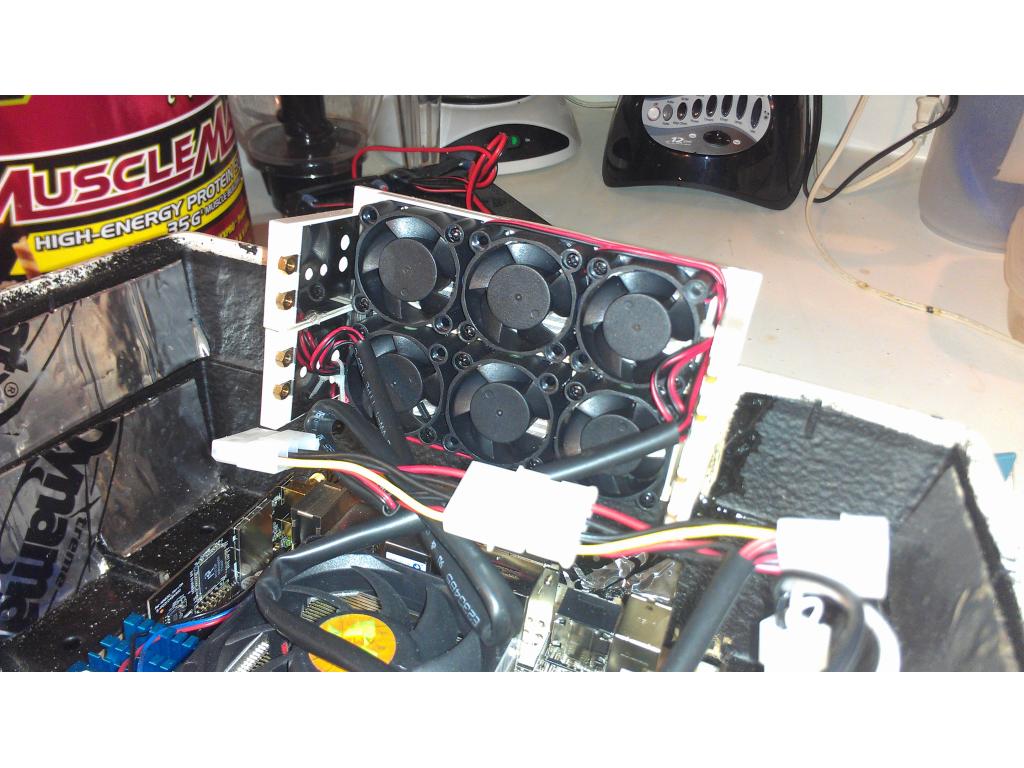
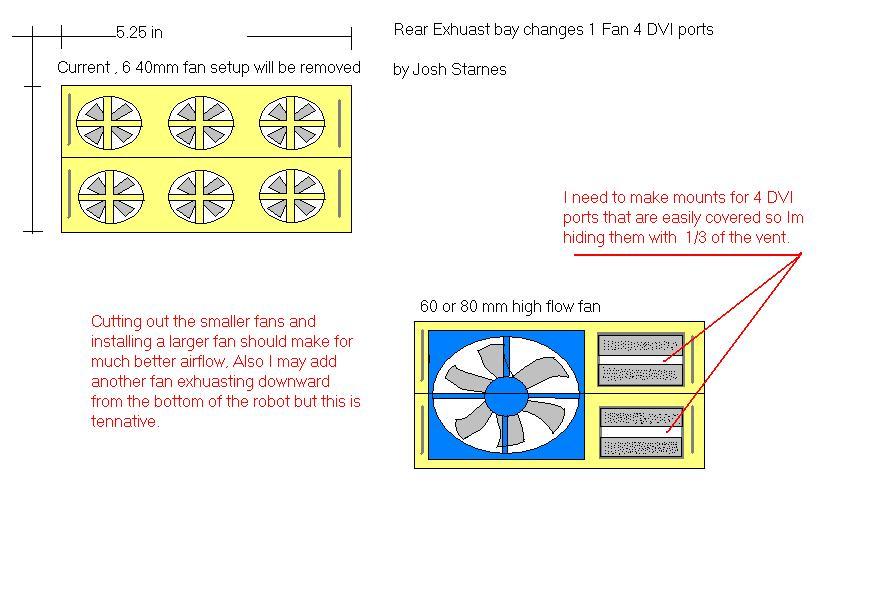
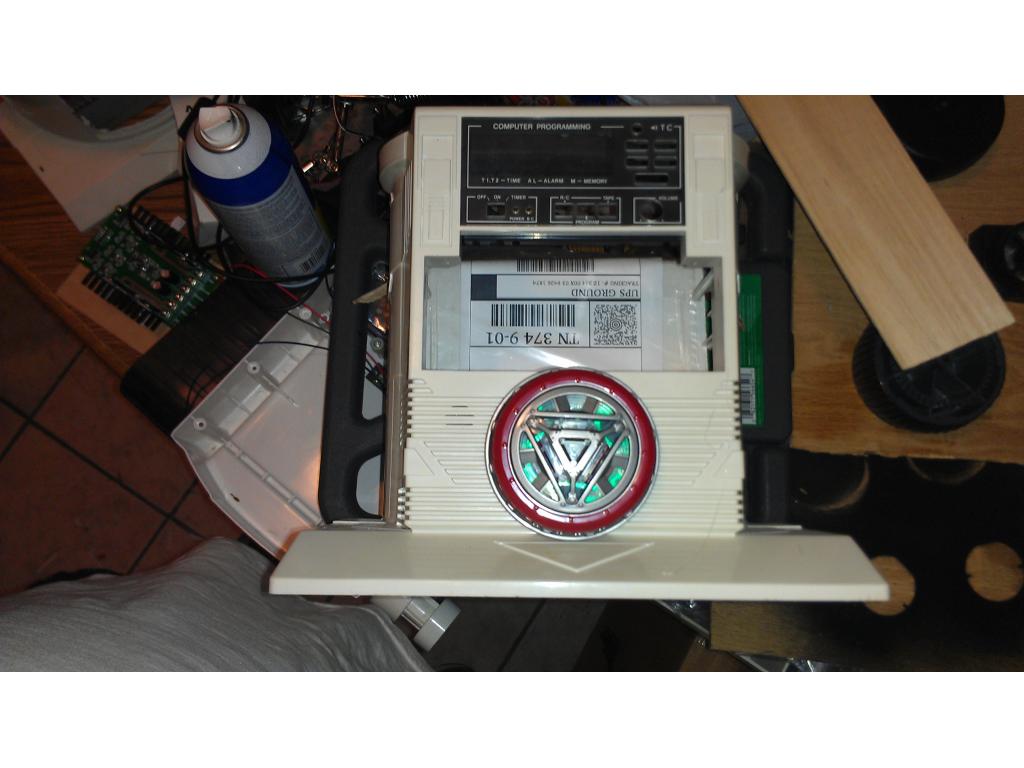
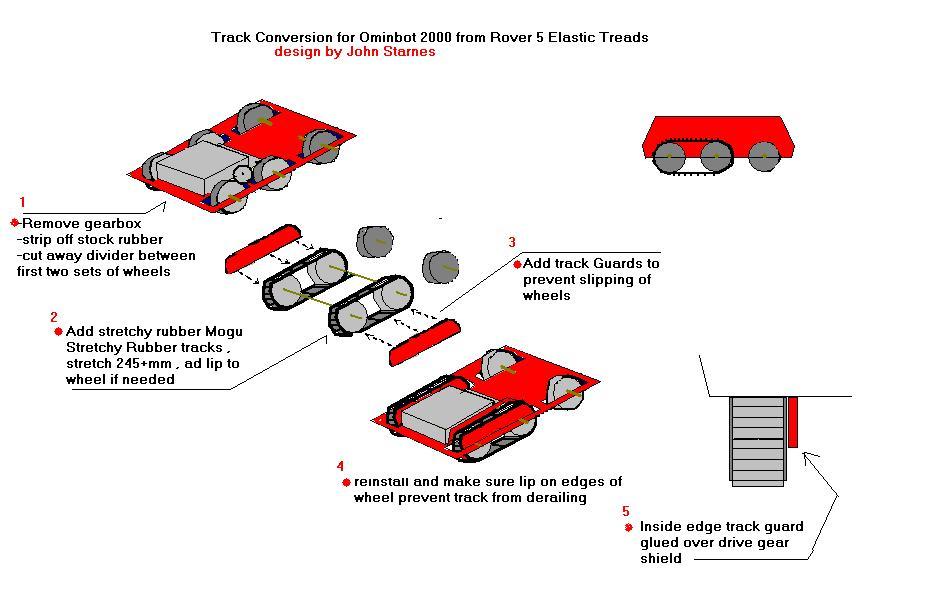
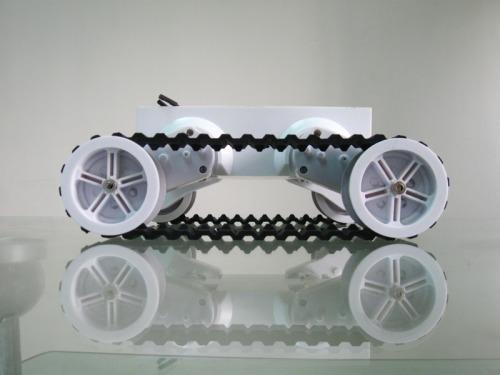
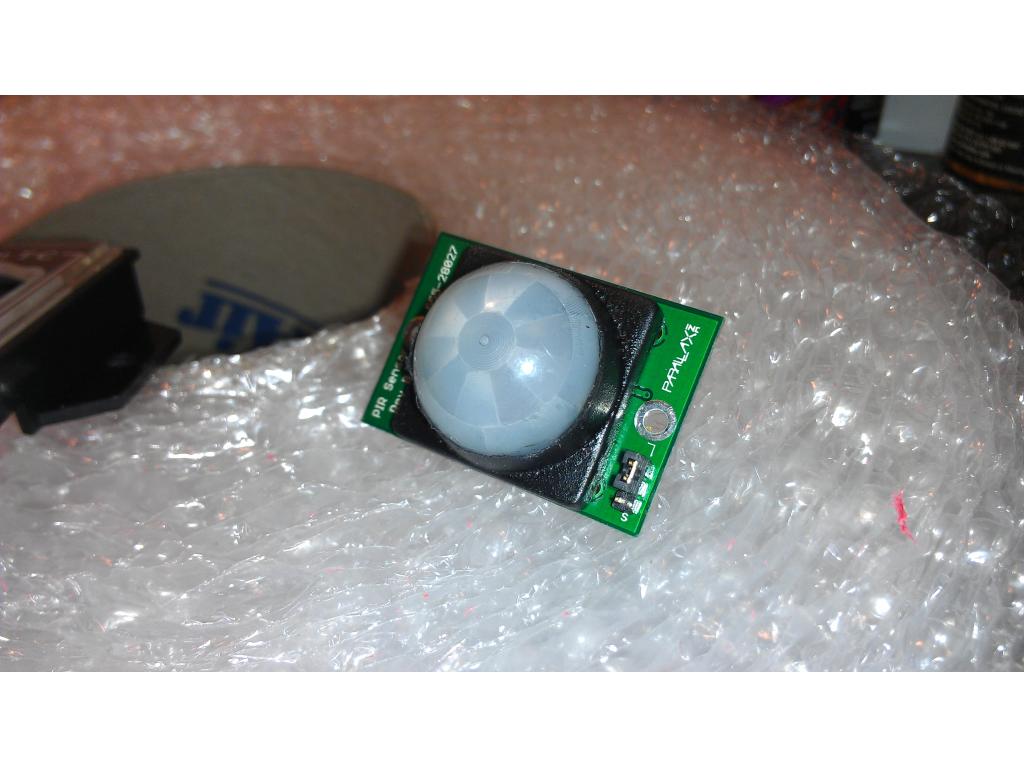
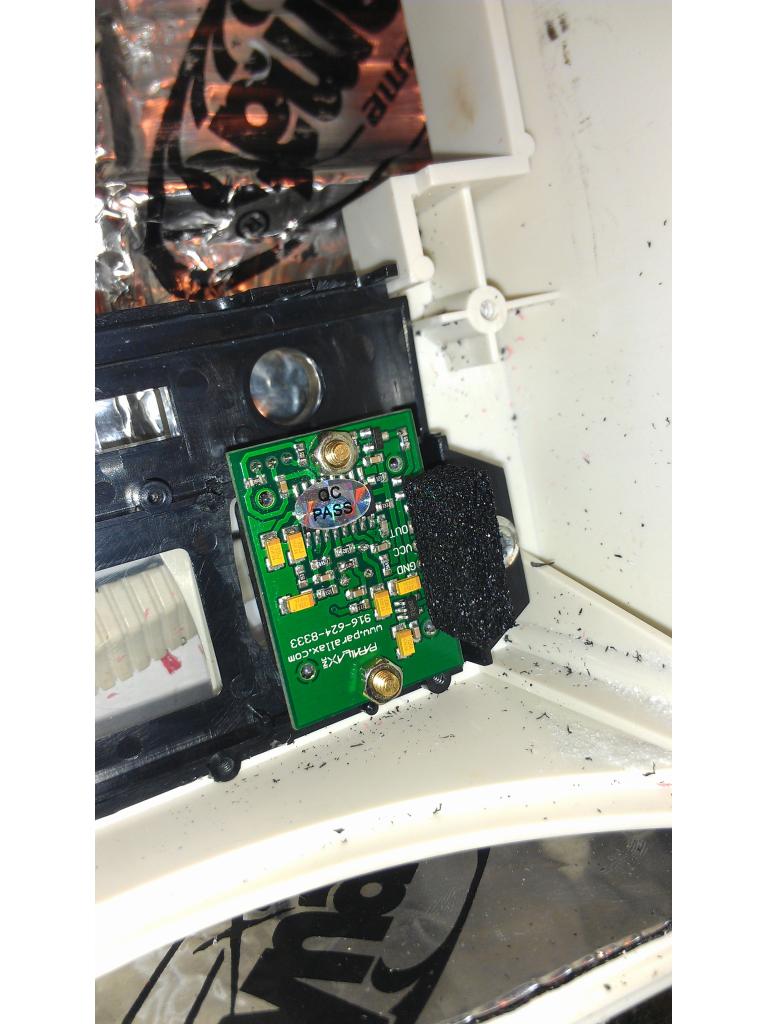
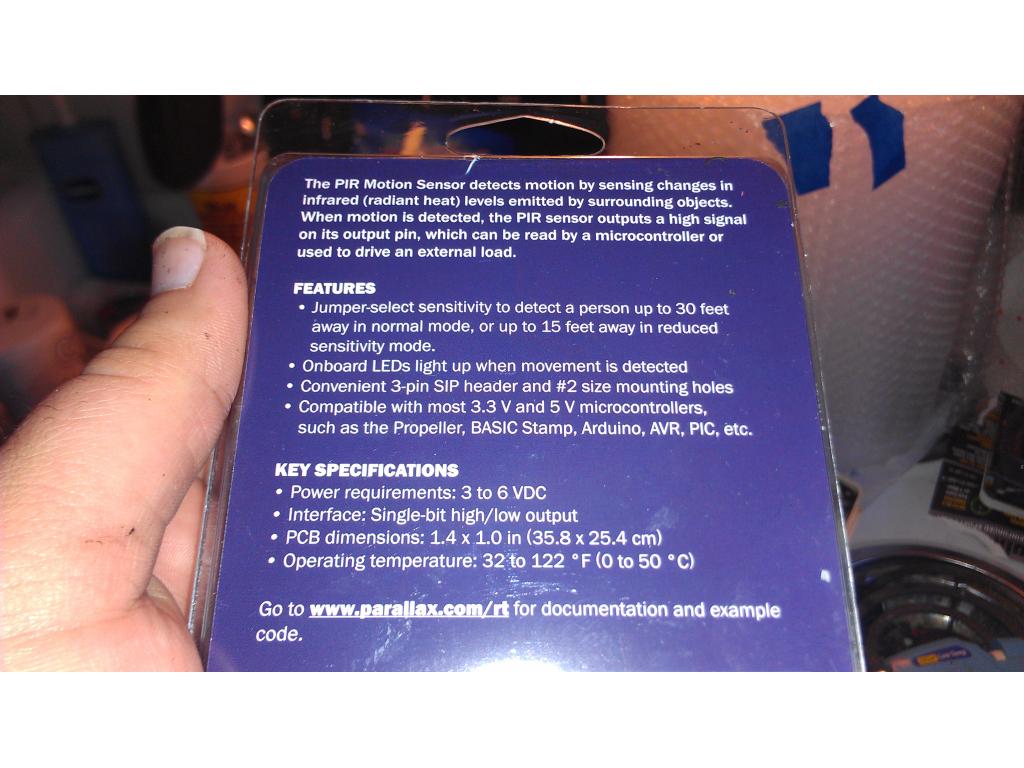
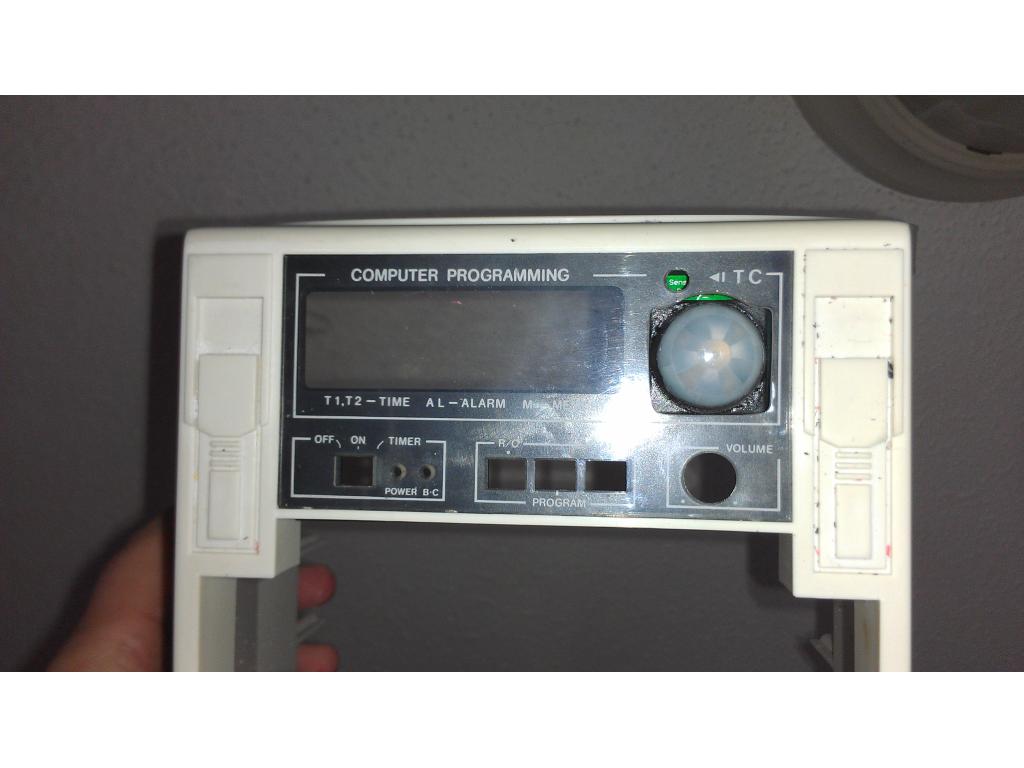
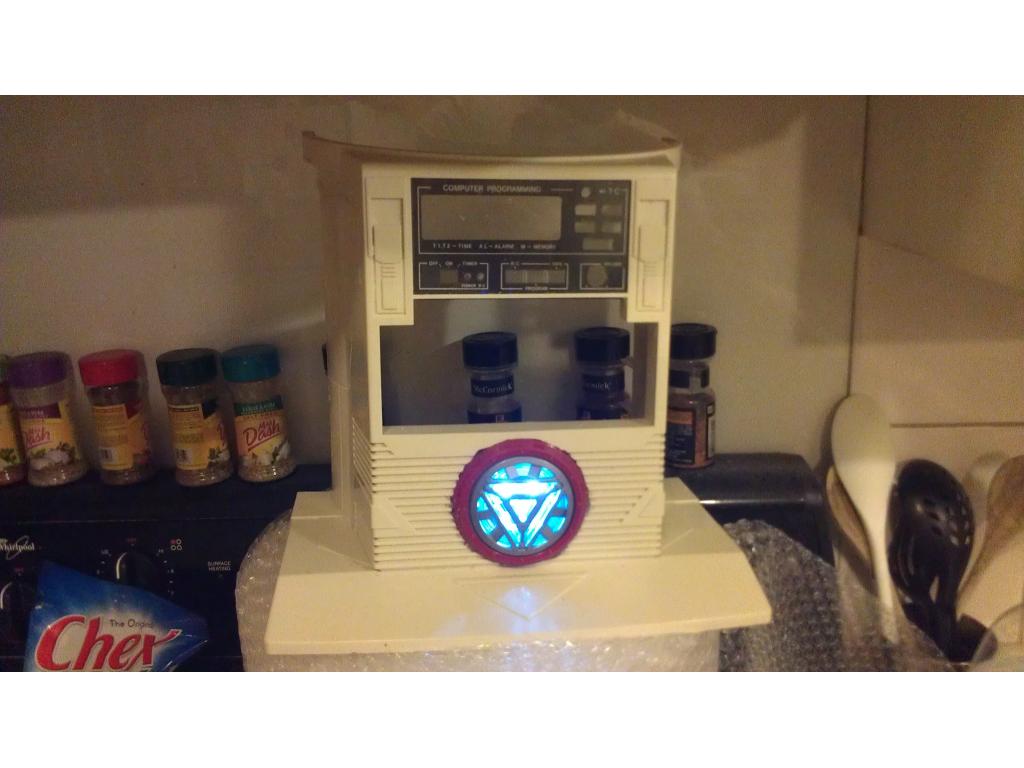
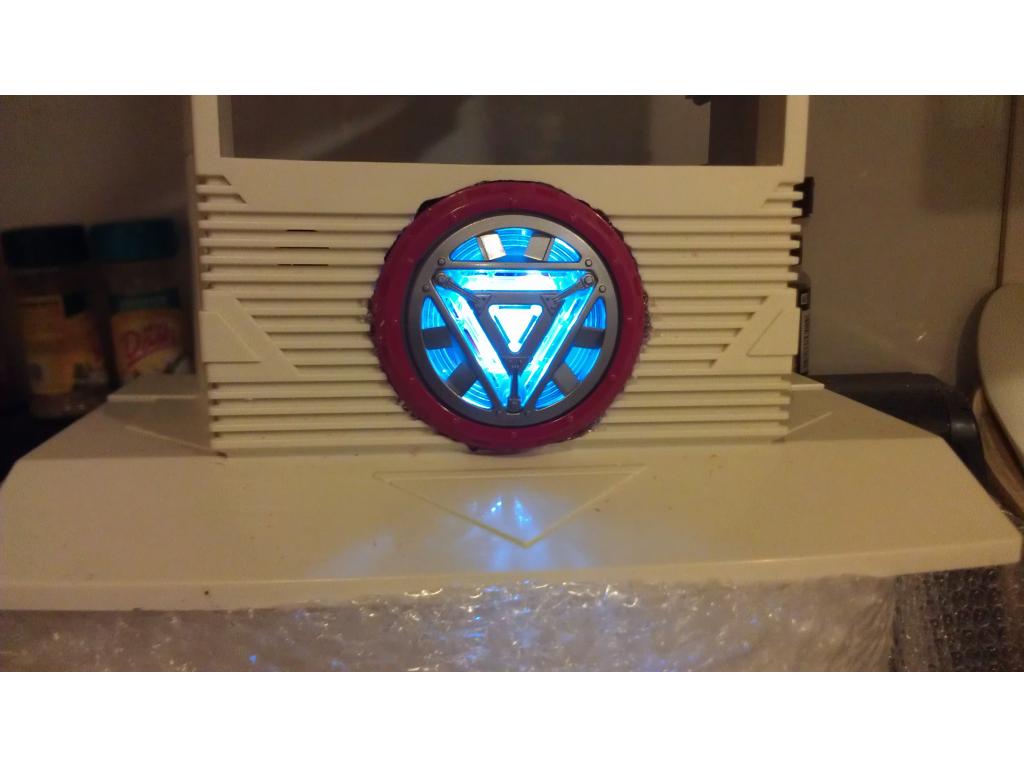
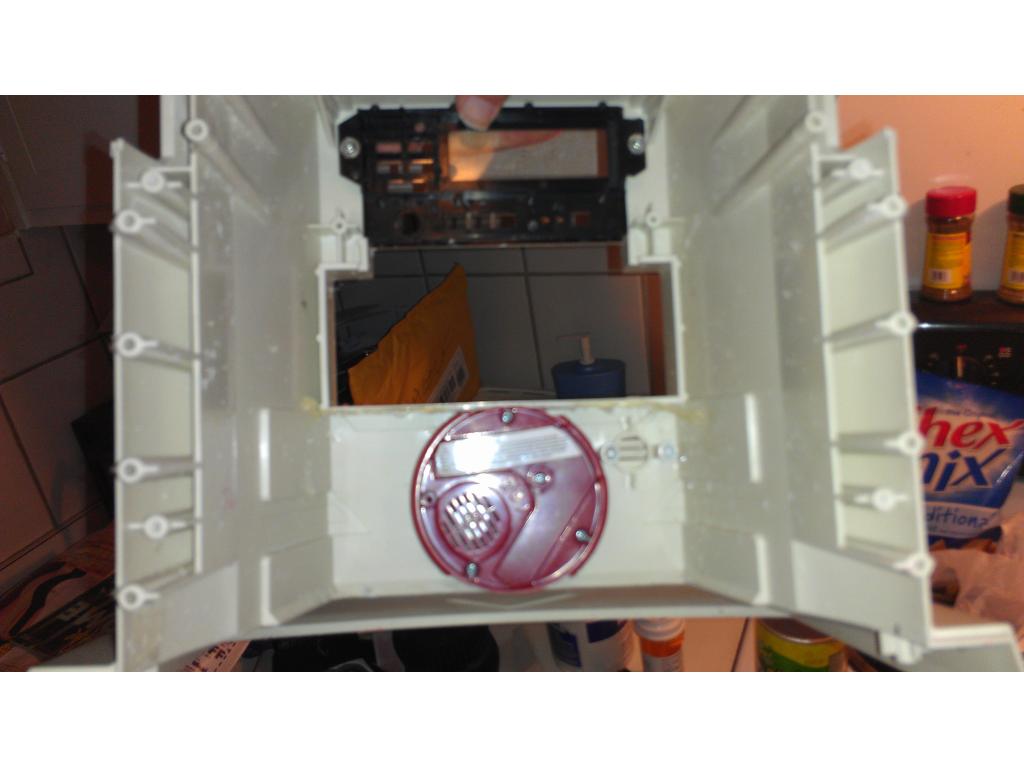
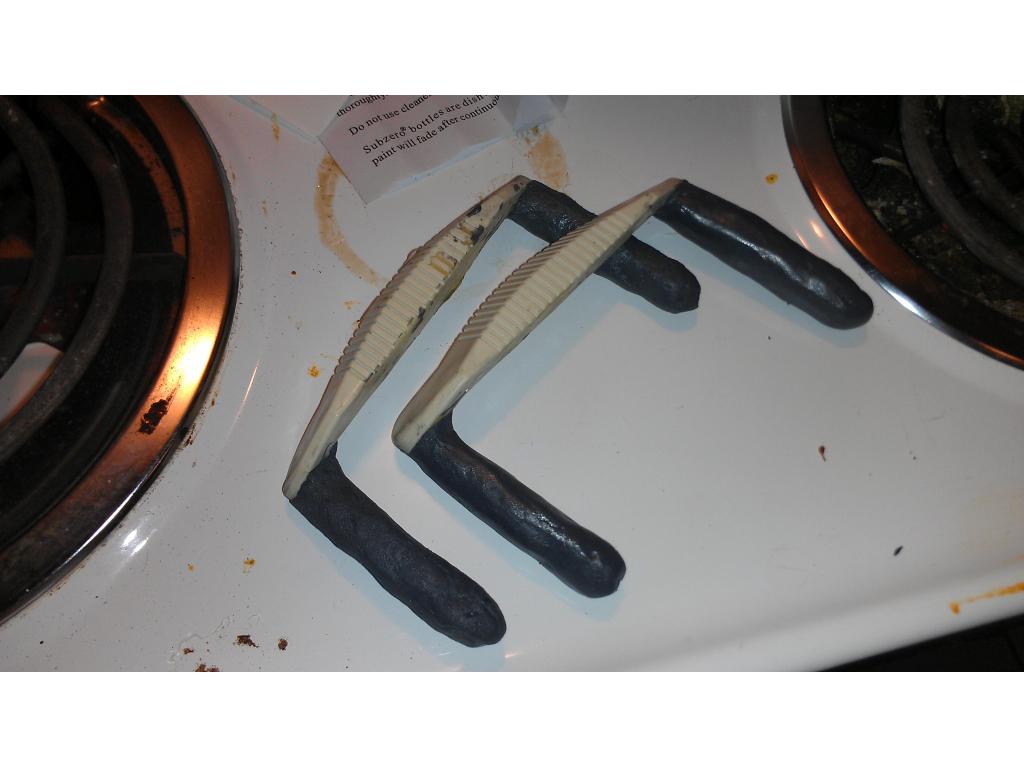
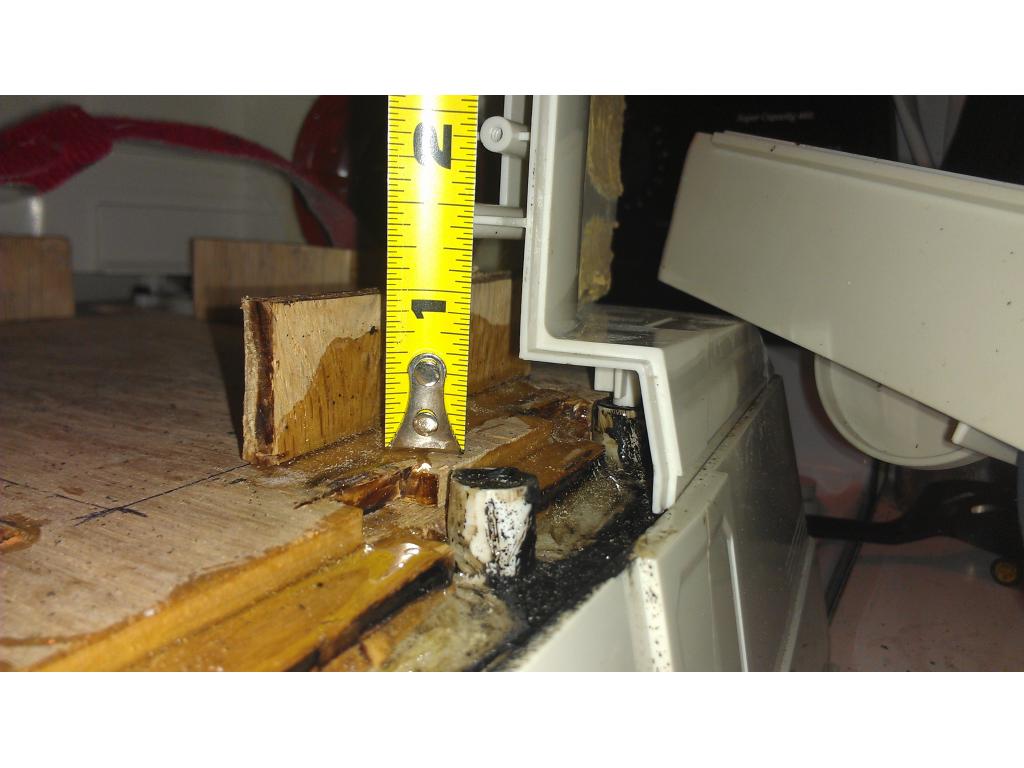
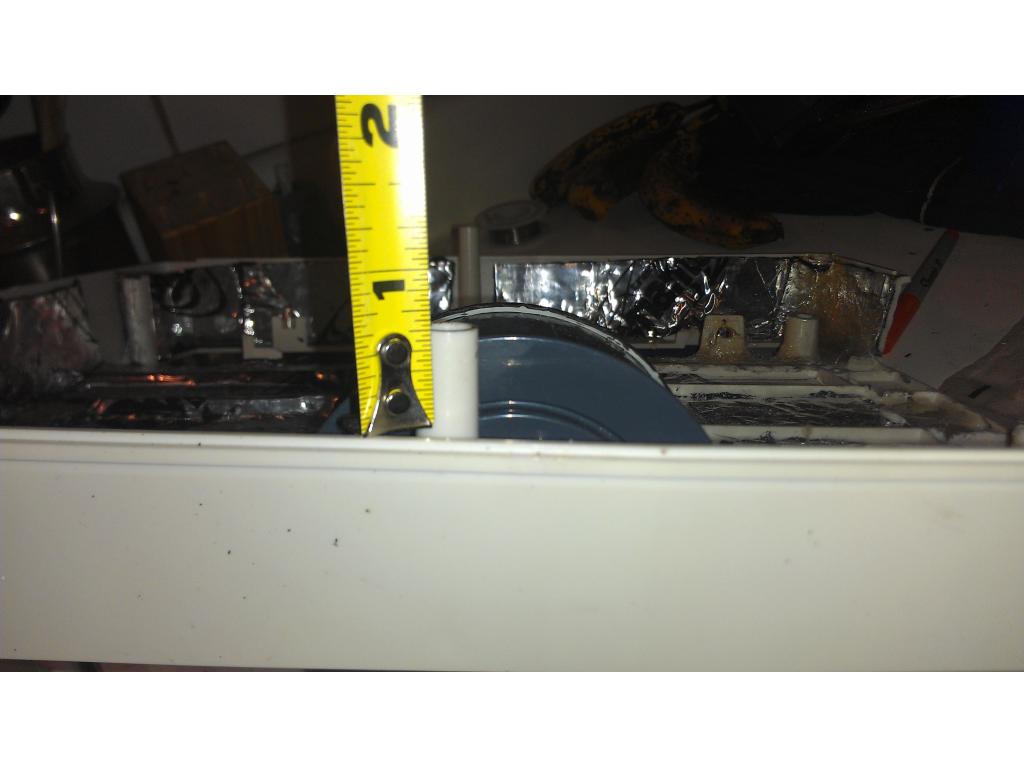
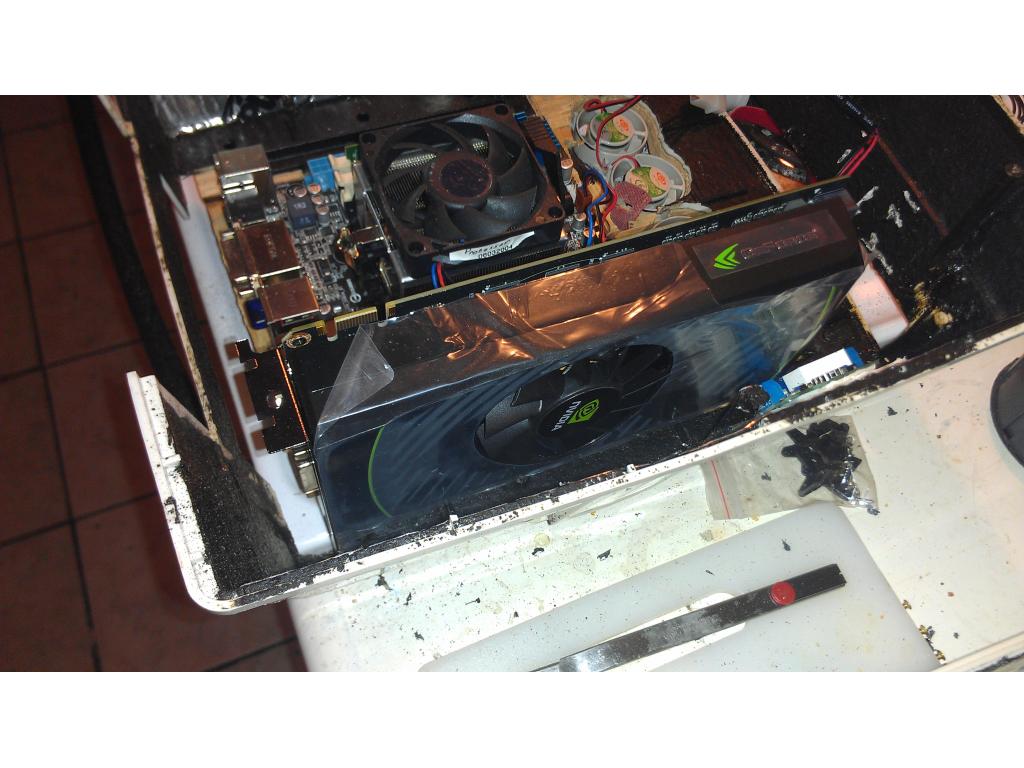
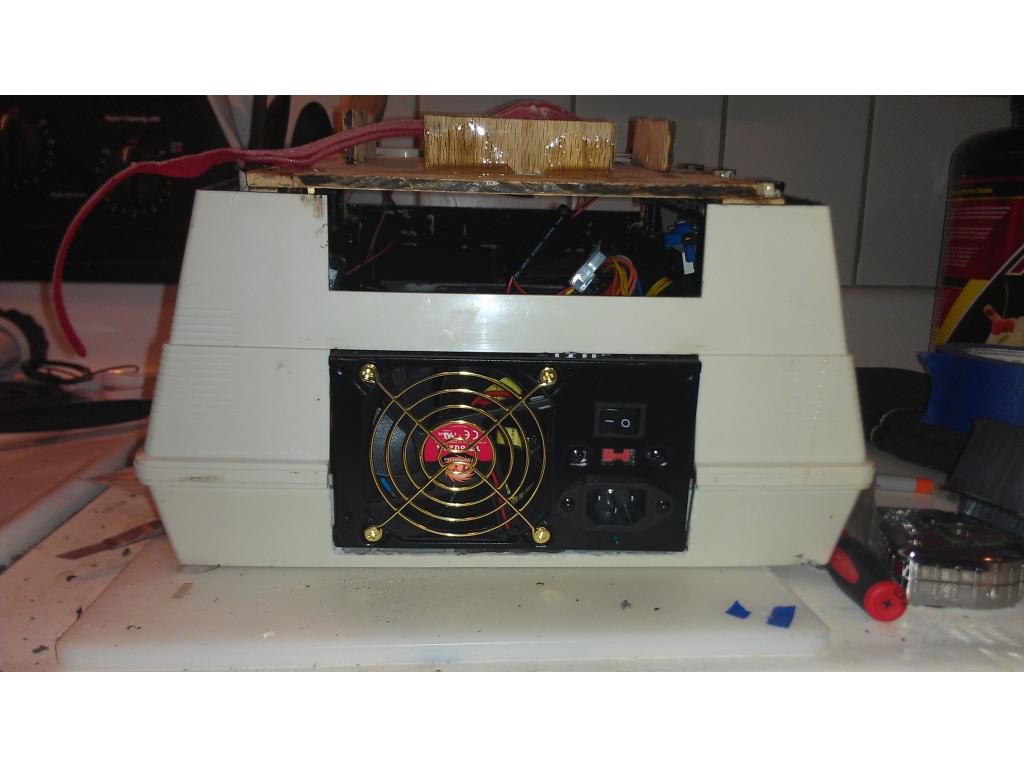
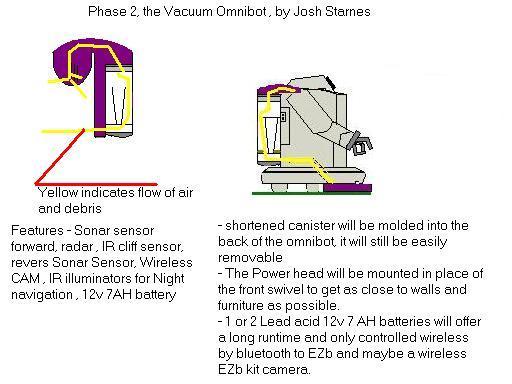
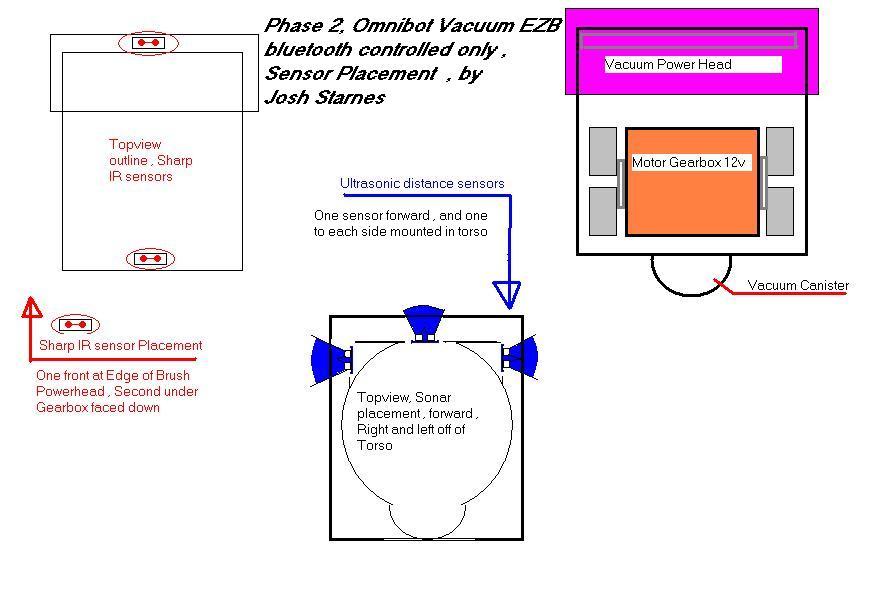
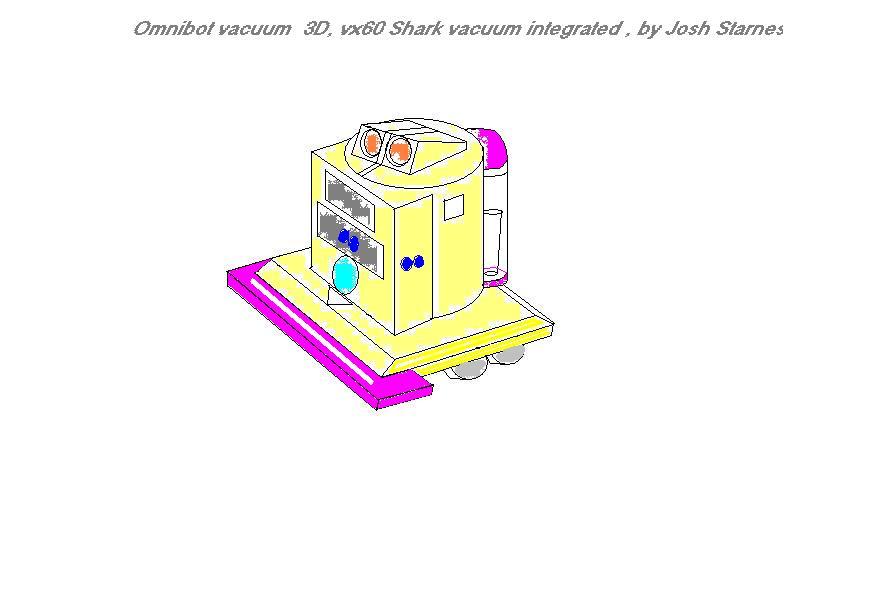
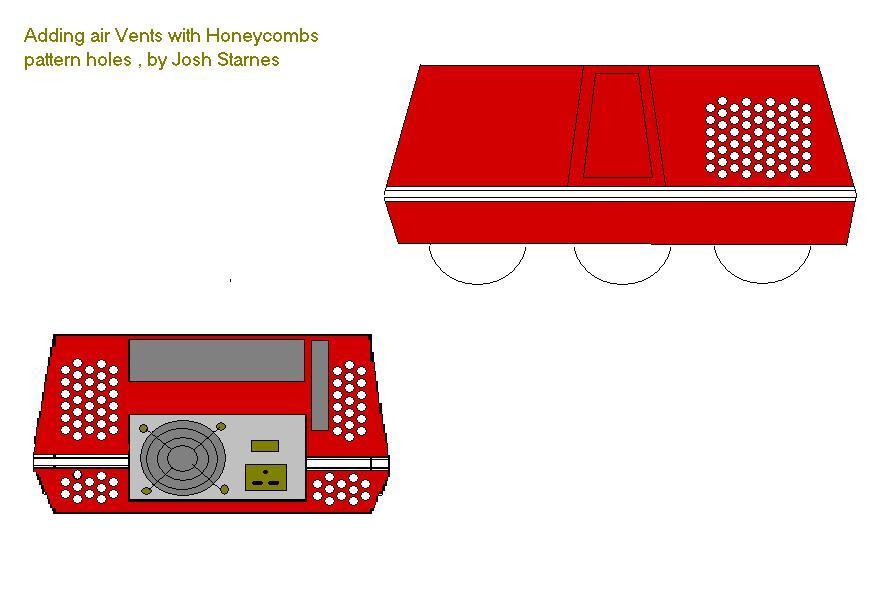
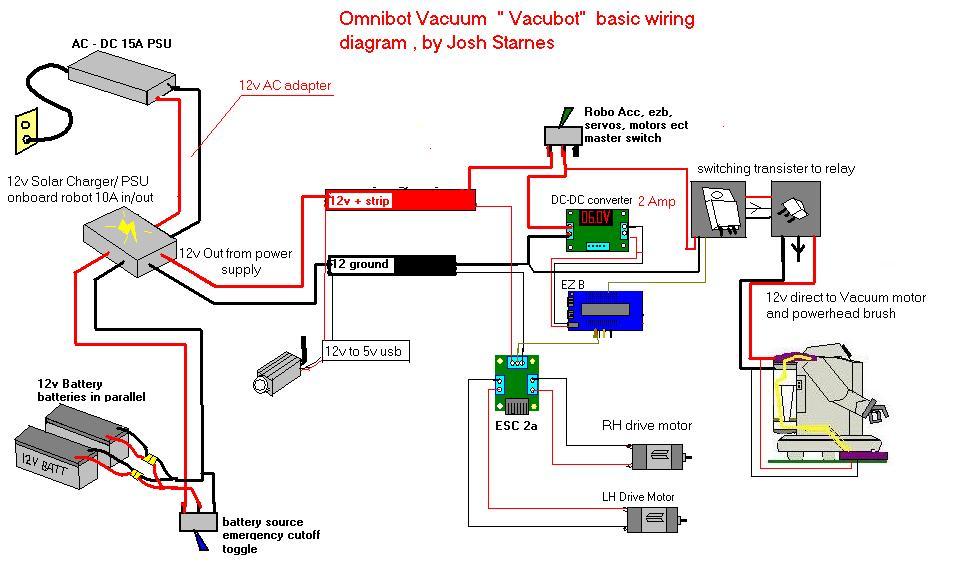
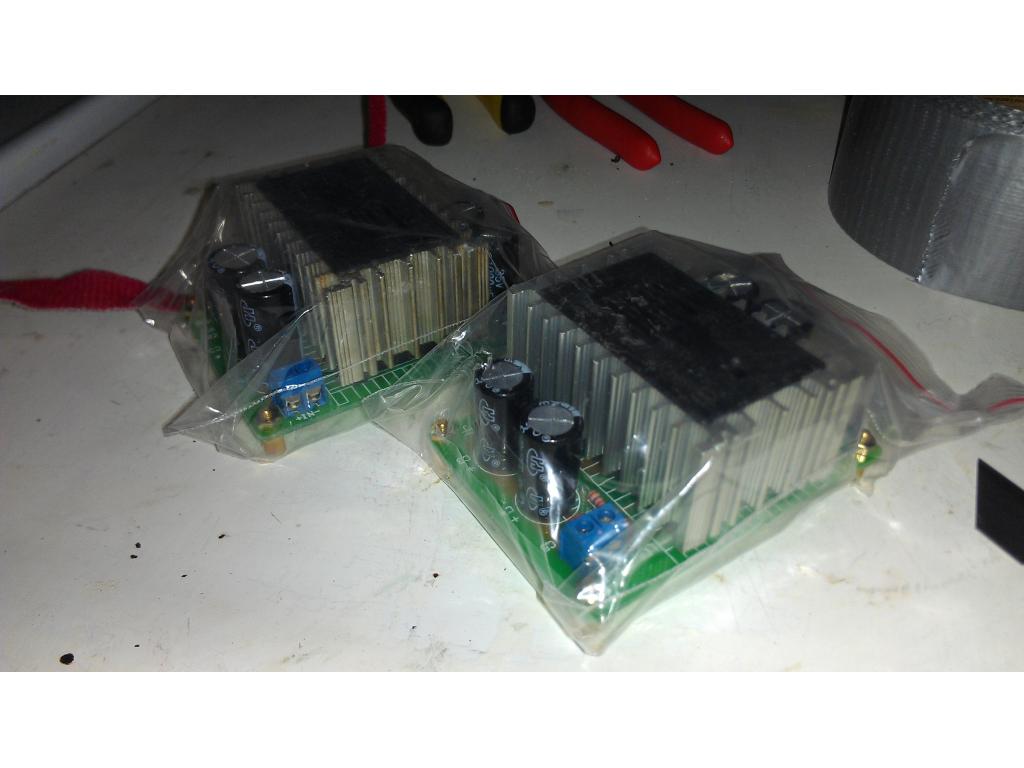
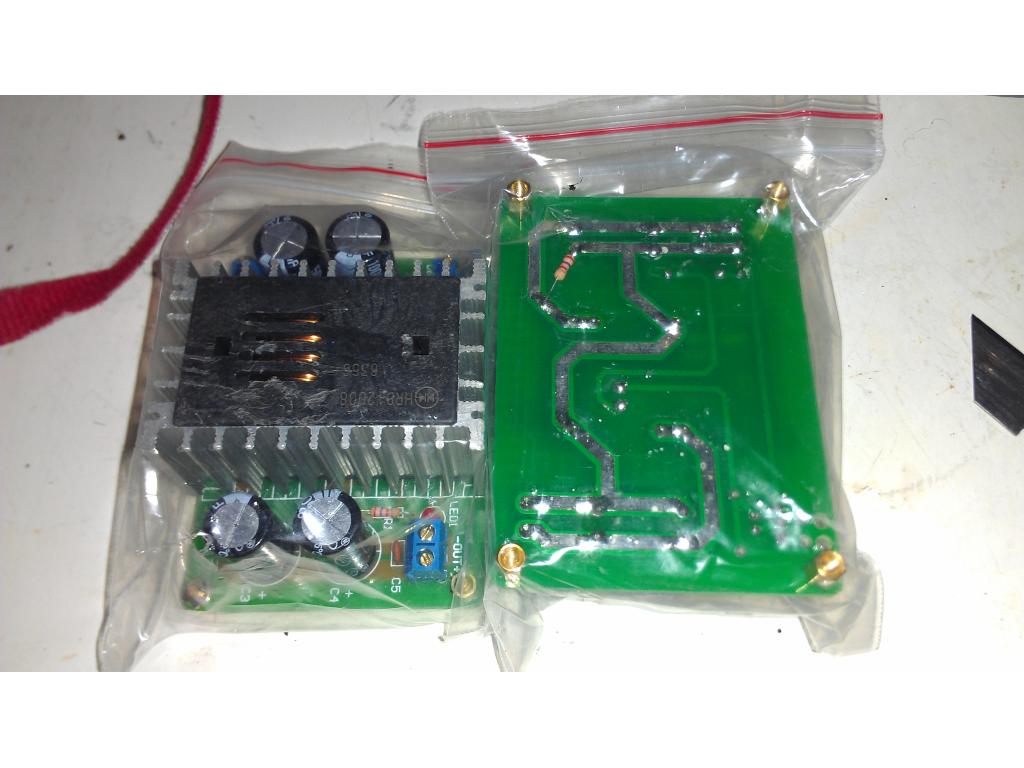
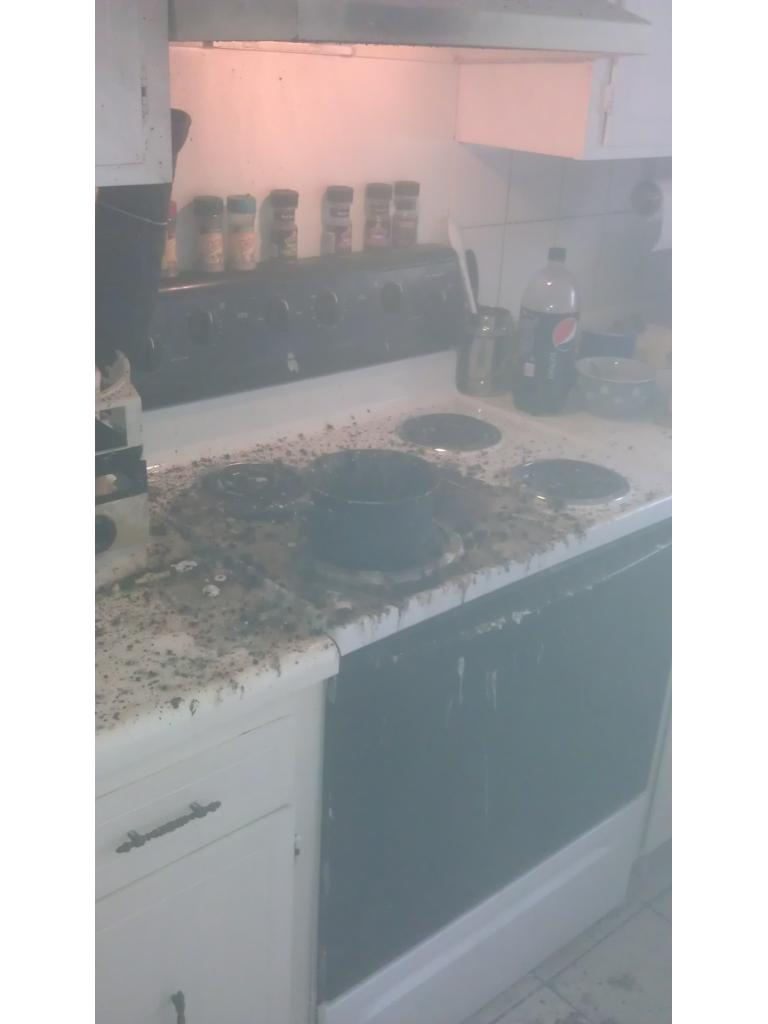
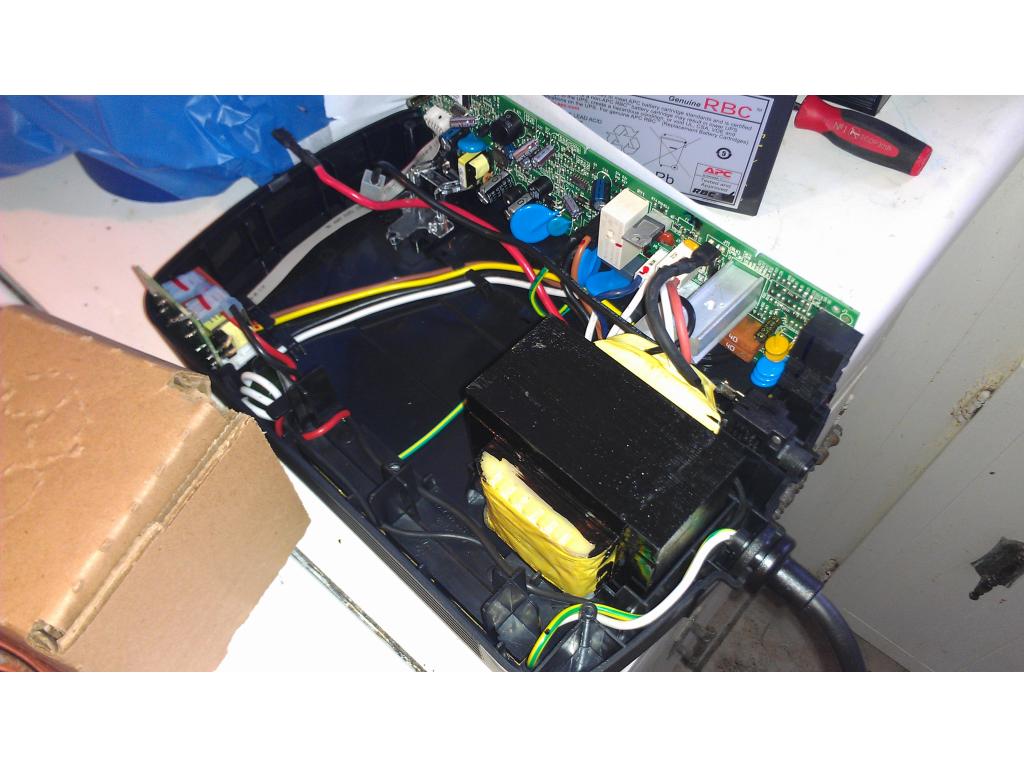
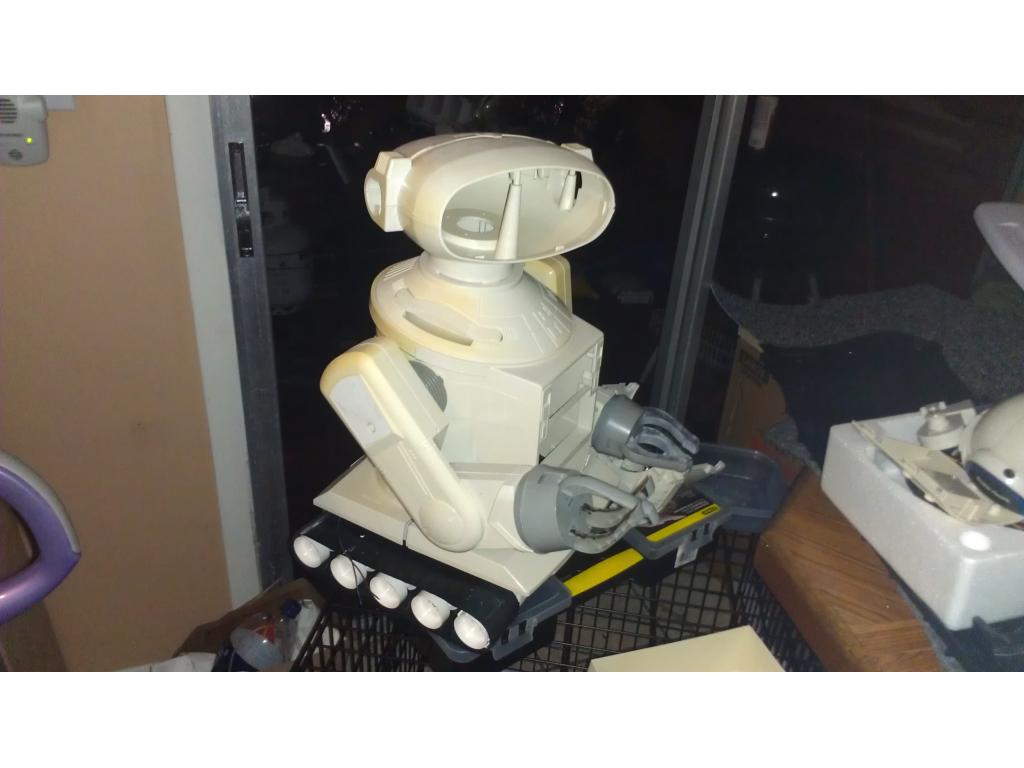
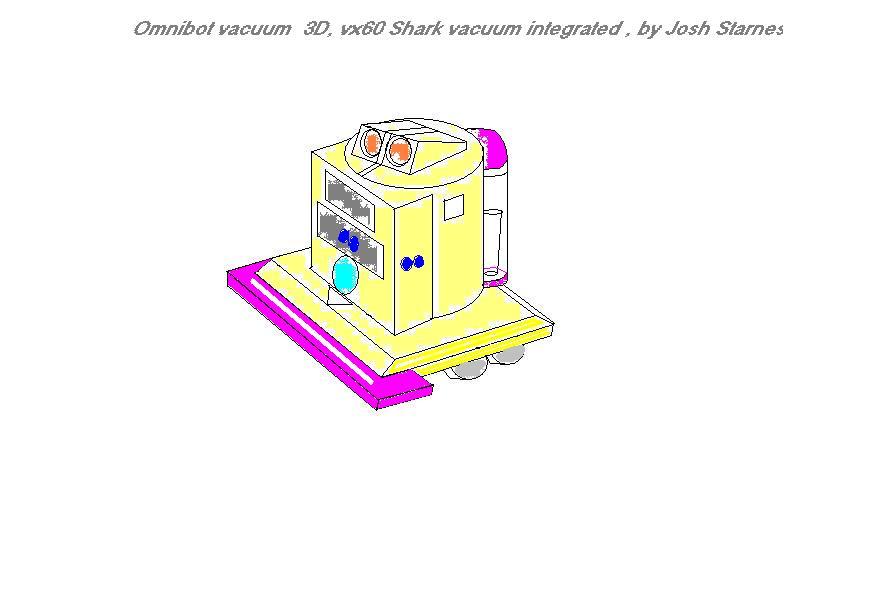
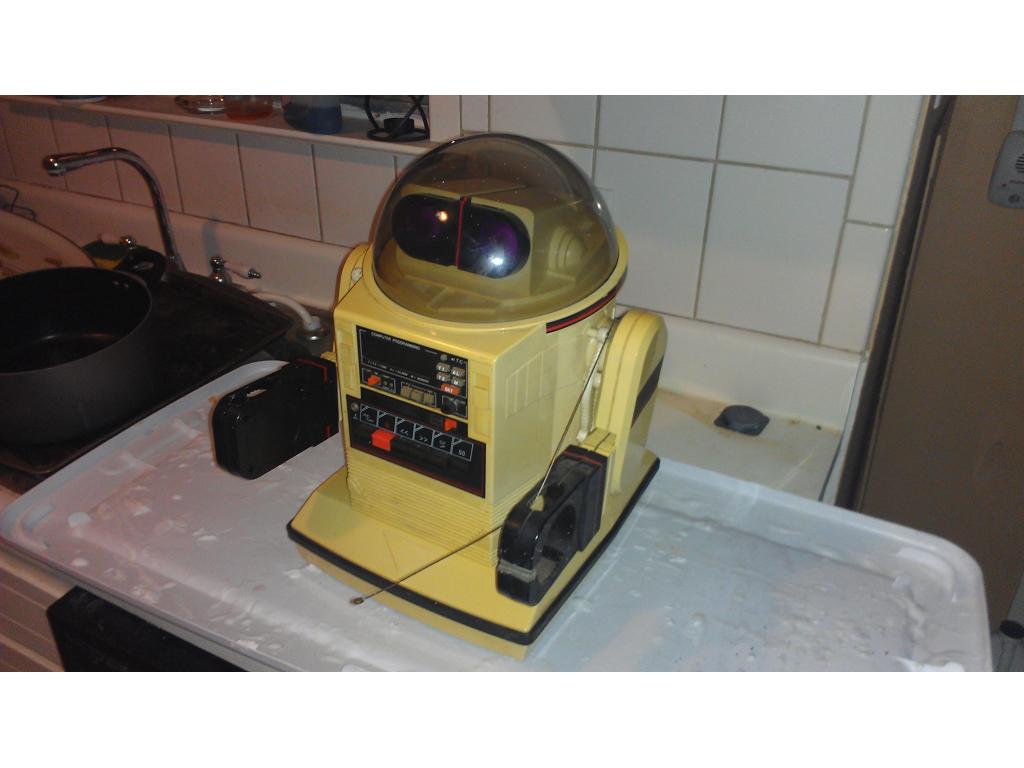
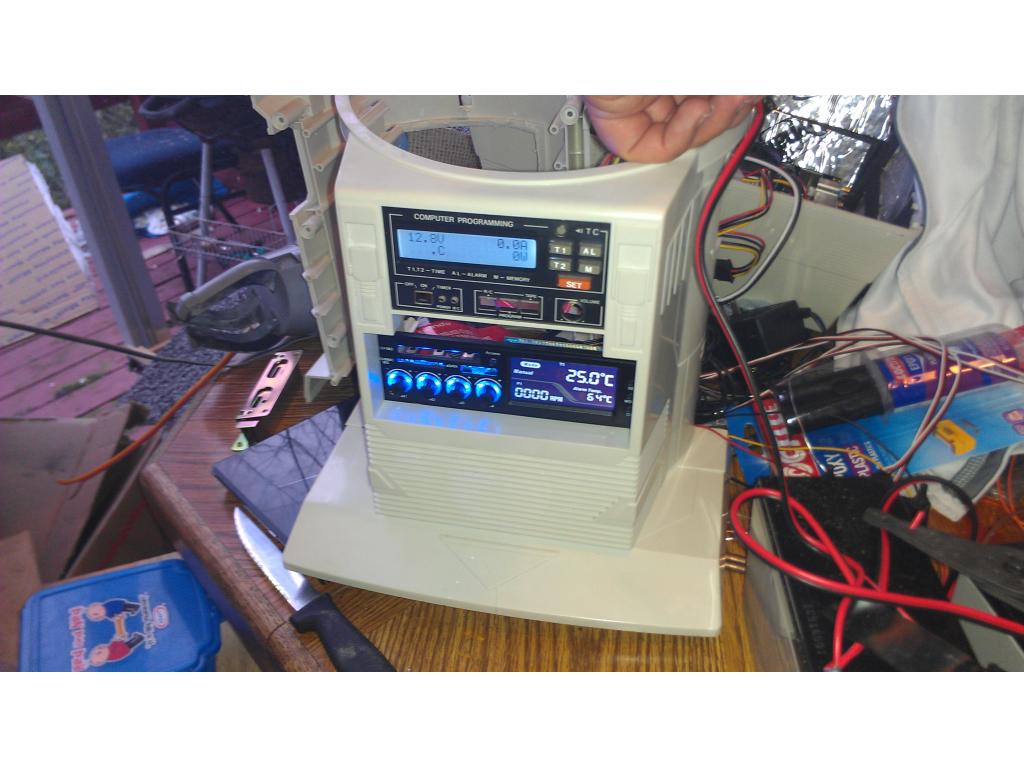
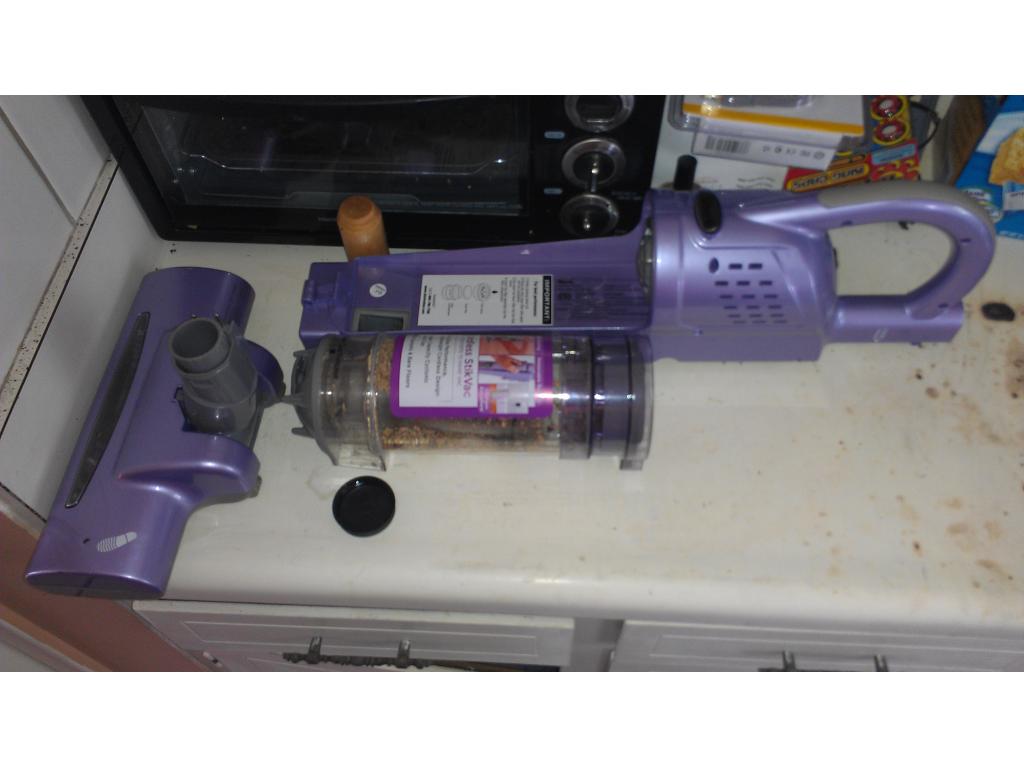
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.
By jstarne1
— Last update
Discover more robots
Mickey666maus's UNITY LINK / ARC
Link Unity 3D to Synthiam ARC using Flask and Python to send virtual servo positions to real servos, sync motion via COM...
DJ's Voice Recognition Robot
Cookie Monster robot showcases EZ-B voice recognition and speech synthesis with dynamic phrase-triggered commands and...
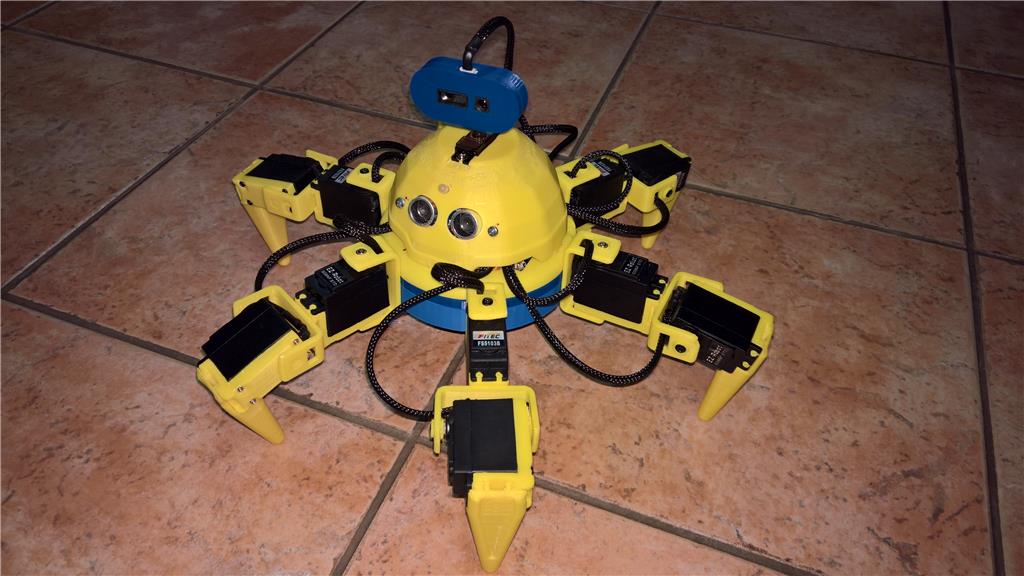
Donesvarc's Printed - Revolution Six
Synthiam ARC: reverse EZ-Robot servos with Auto Position Panel to fix inverted servos on EZ-V3/EZ-V4 Wall-E Six...

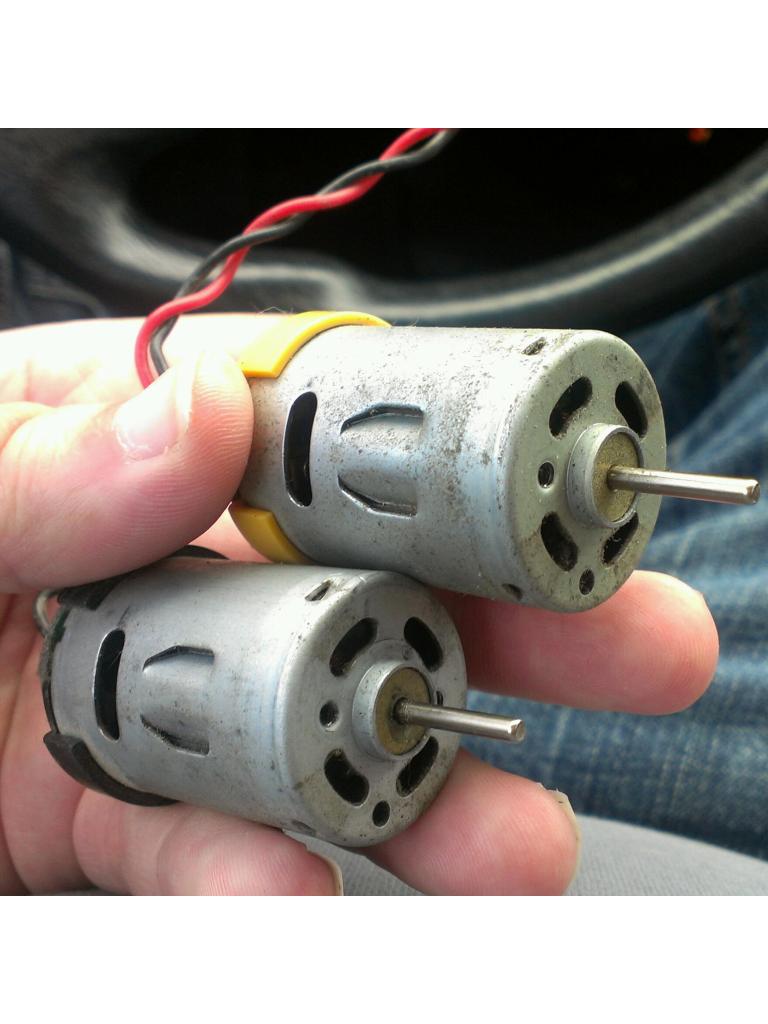
wow 60 lbs thats alot of weight,JOSH have you tried my motors i sent you,they will handle about 70 or more pounds ,using 2 of them,plus with gear box ratio will be more
If fI can make the extra room I would love to try those motors.
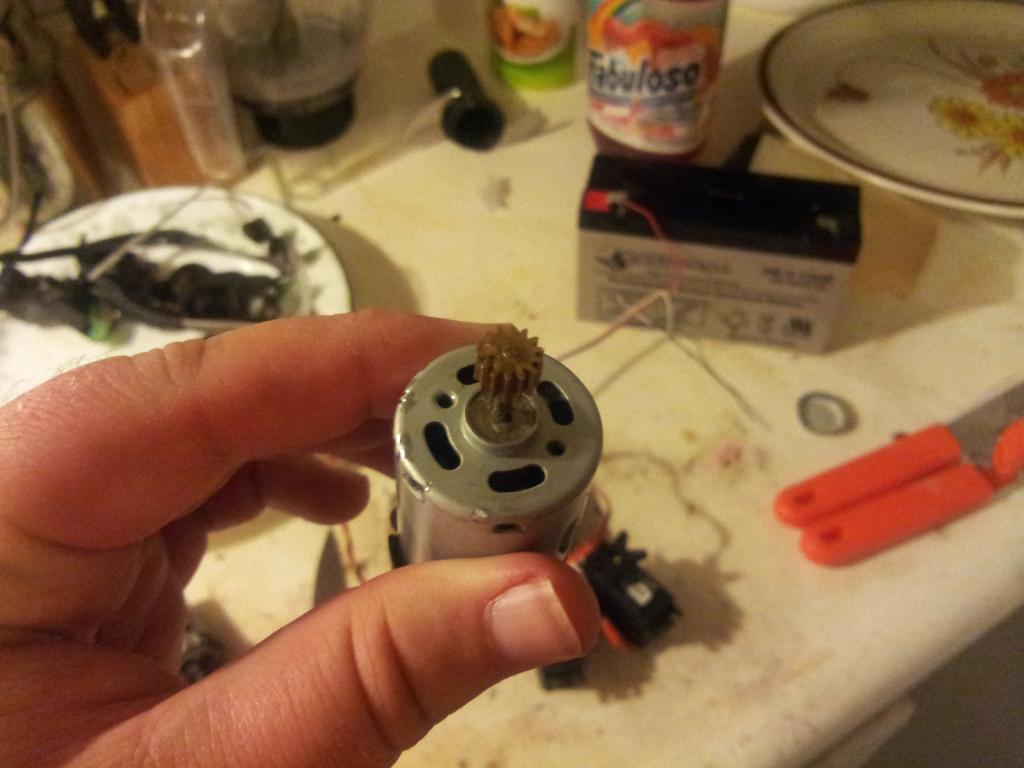
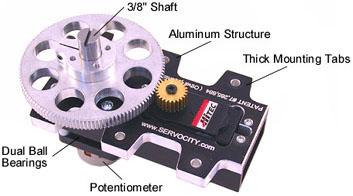
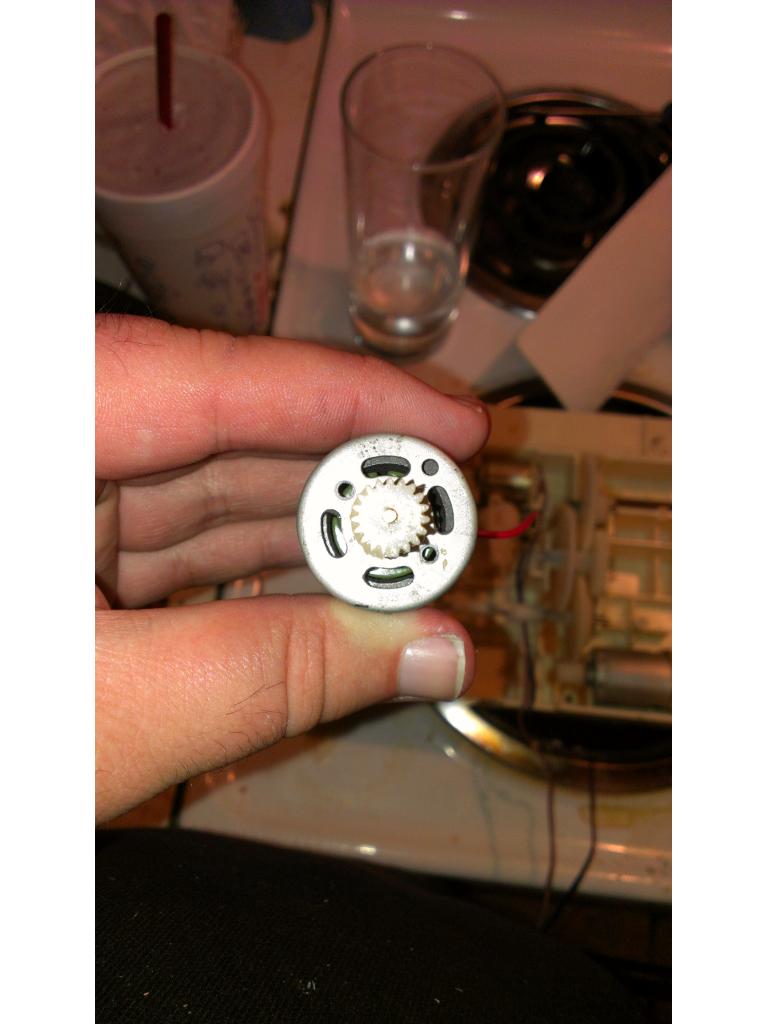
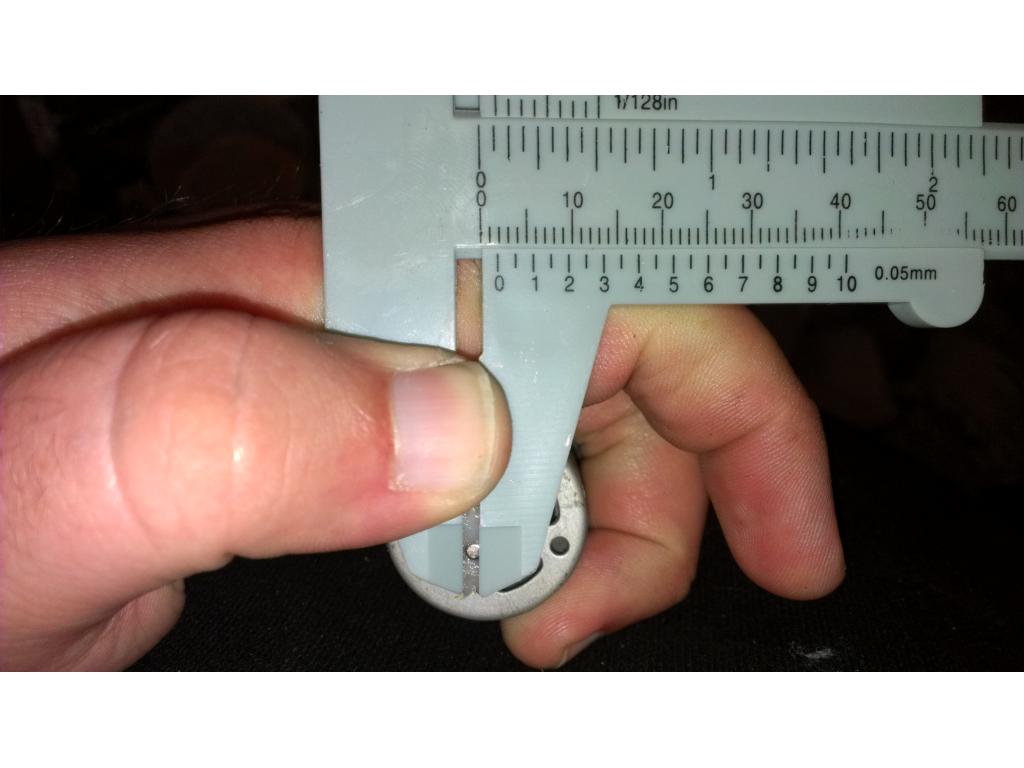
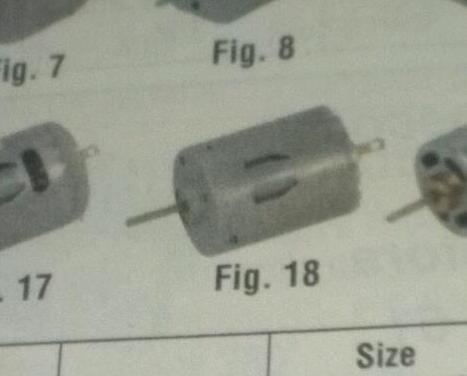
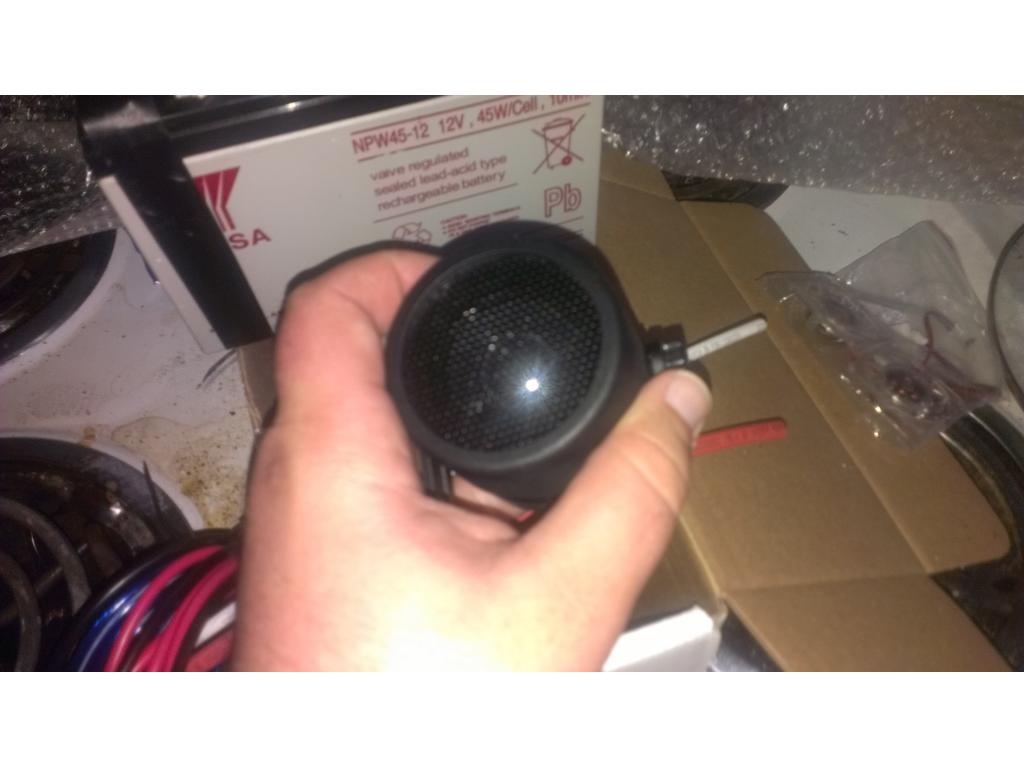
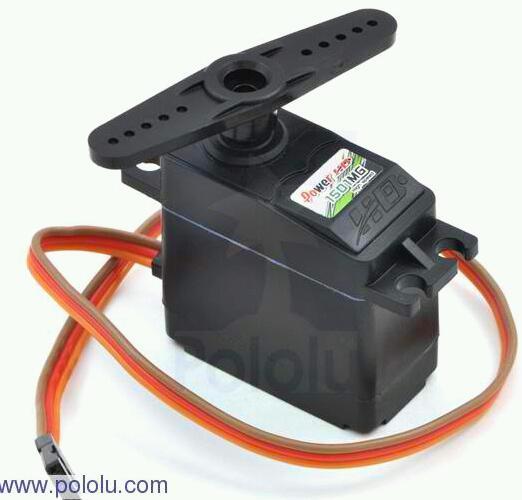
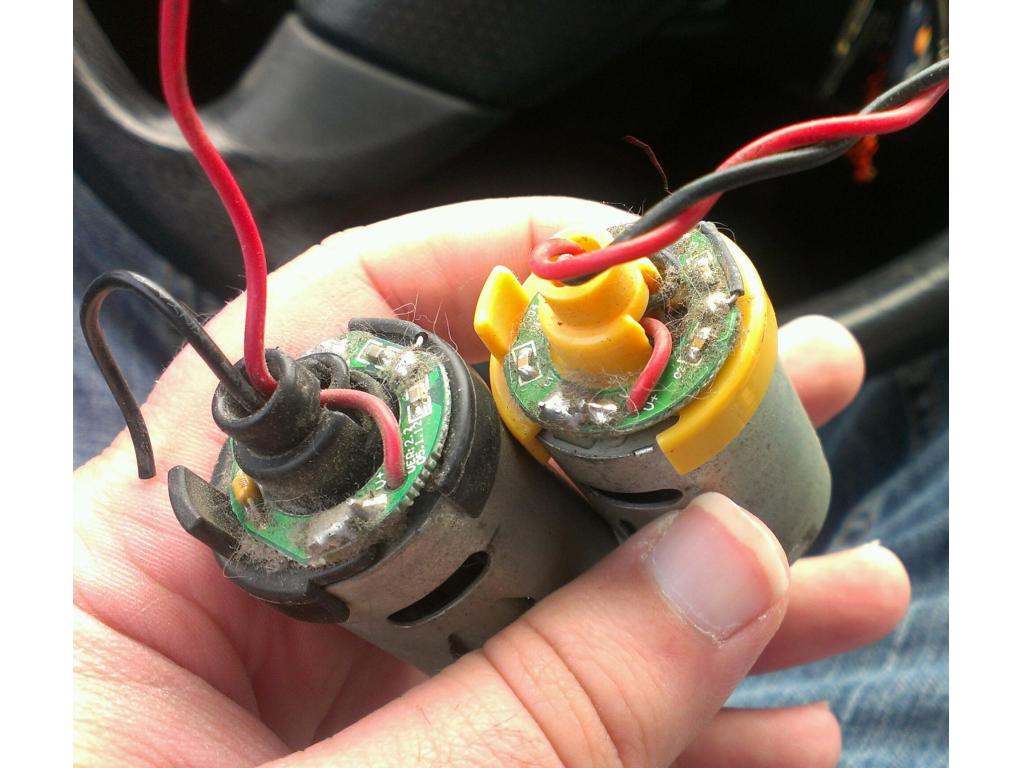
motors will fit,only little longer,but 2 together will fit ok ,with about 1/2 inch to spare only the pinon gear needs to be changed i have tried it on mine,until i changed over to tracks,needs 12 volts i think it has magnetic encoder on it,working on a desgn to interface to it,or has a analog output to EZB
I only see power wires , how do I connect a encoder signal?
maybe those i sent you dont have the encoder wheelon them
Oh ok.
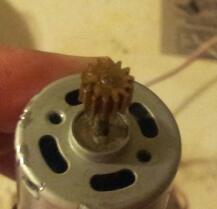
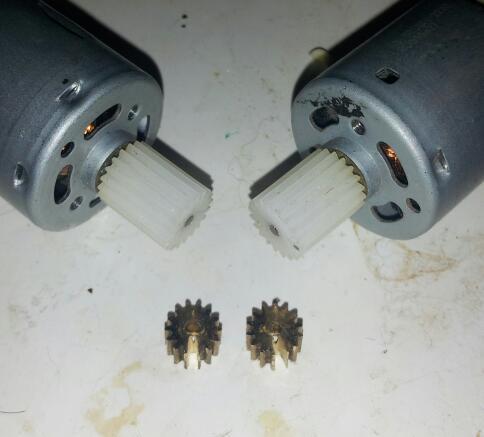
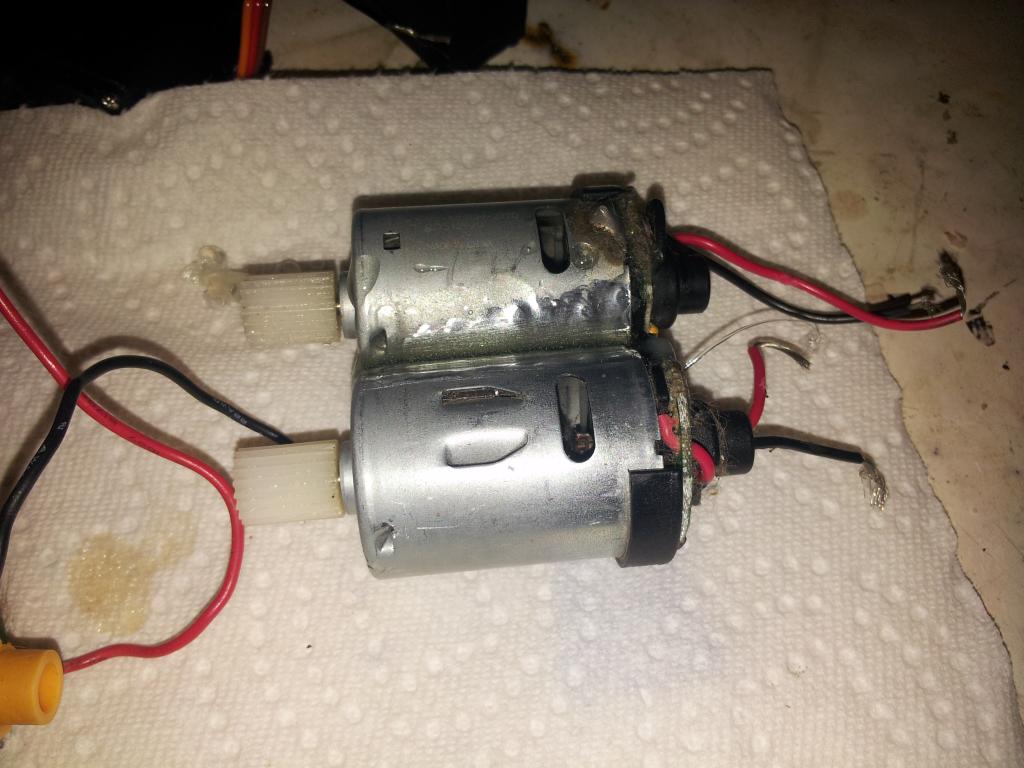
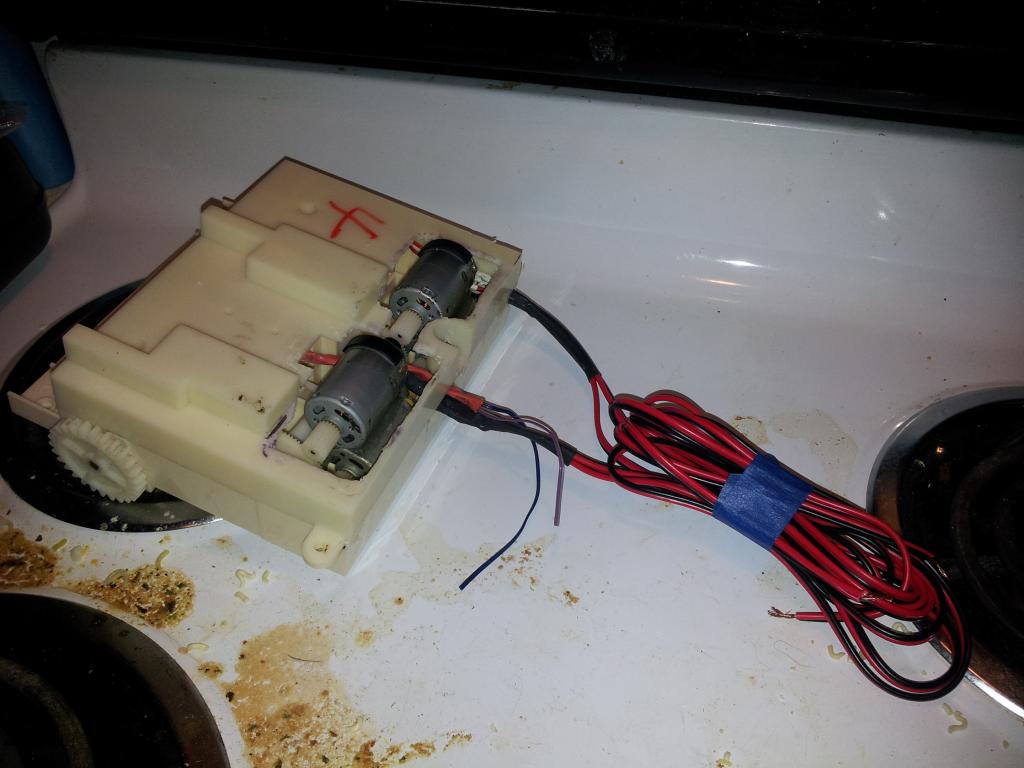
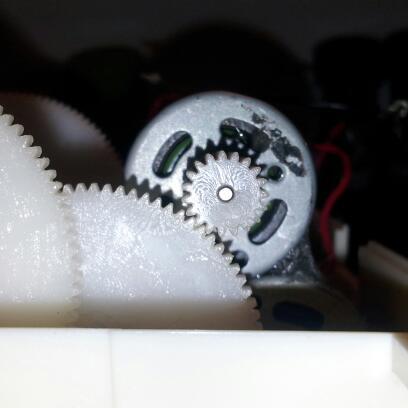
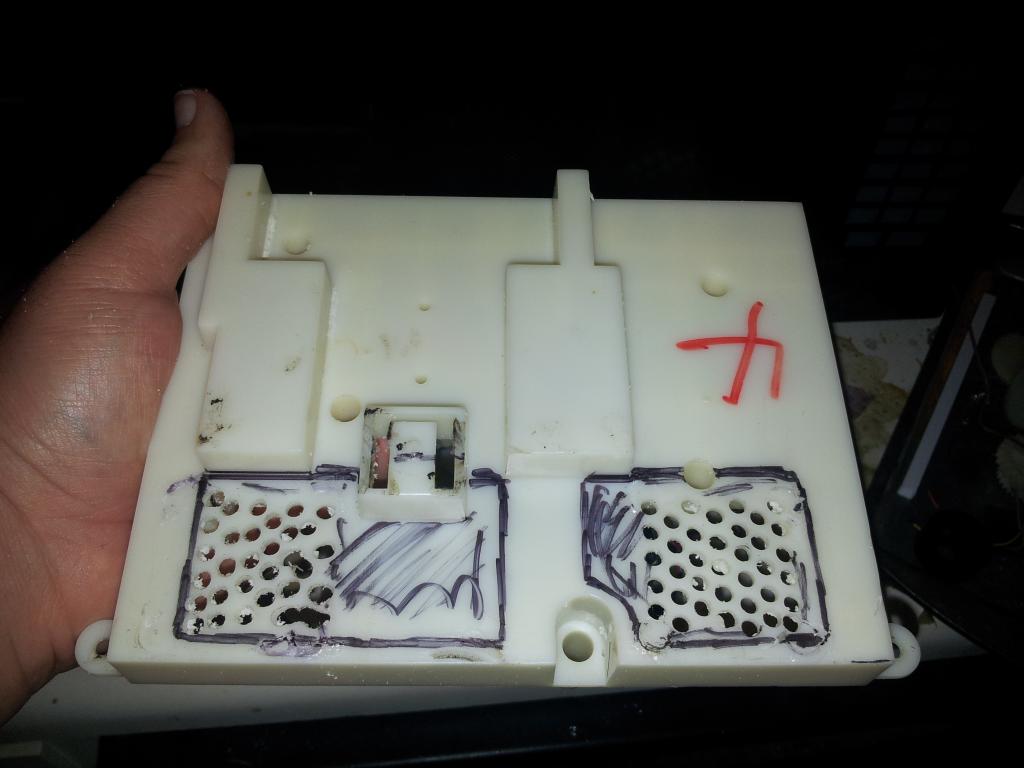
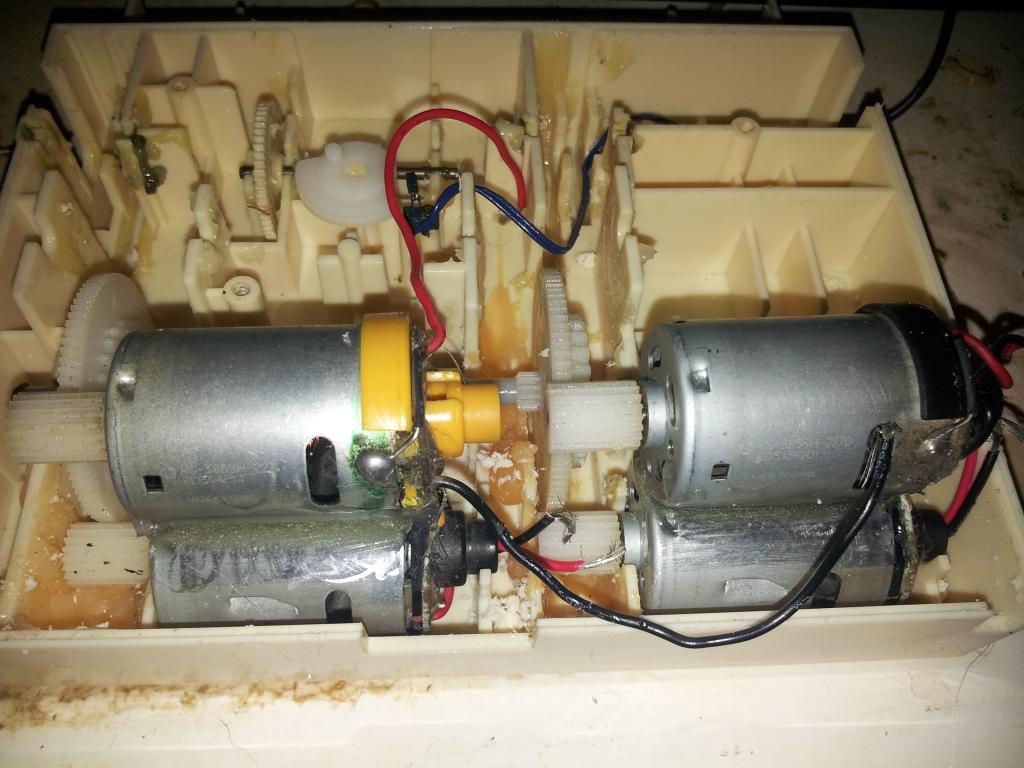
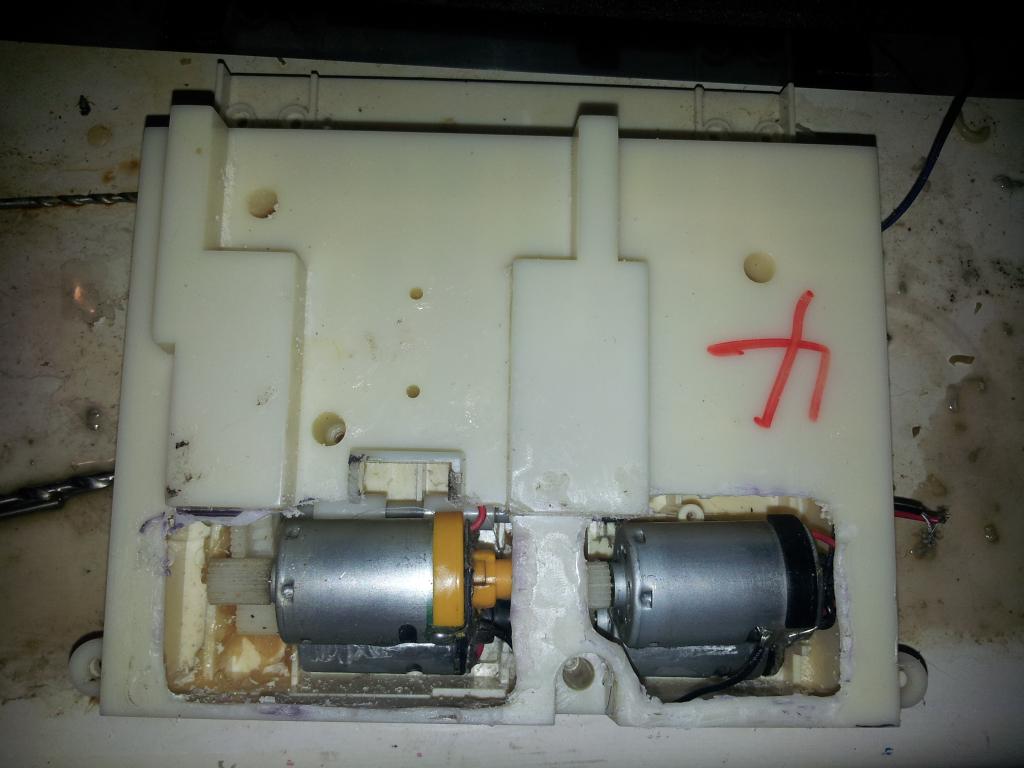
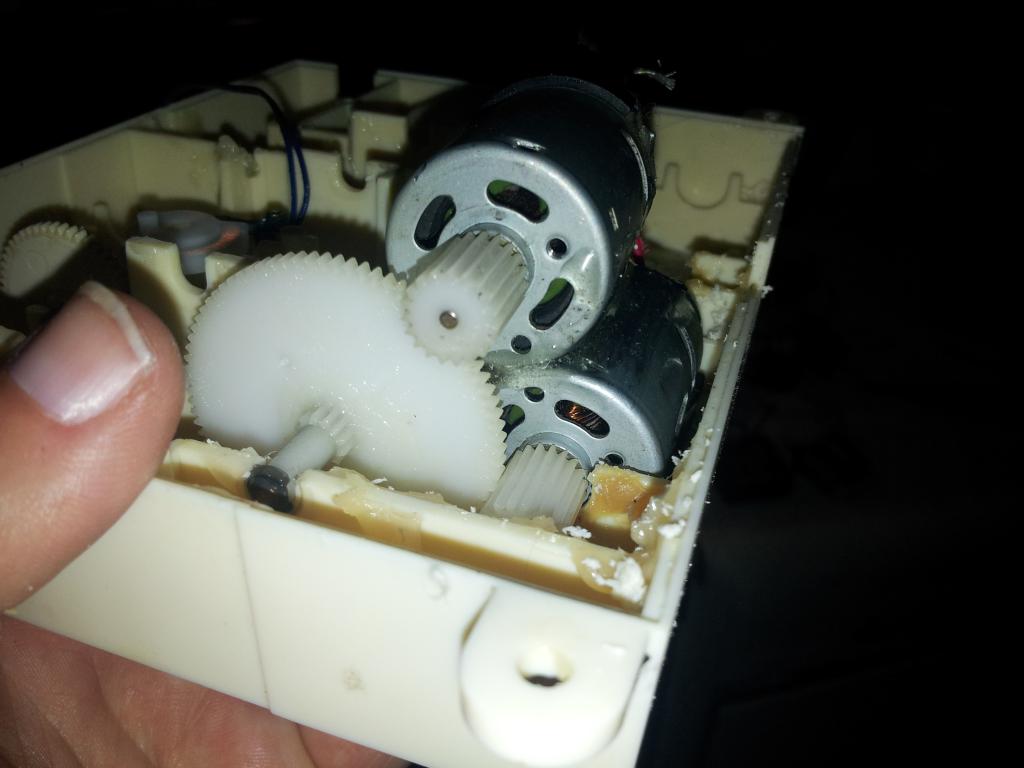
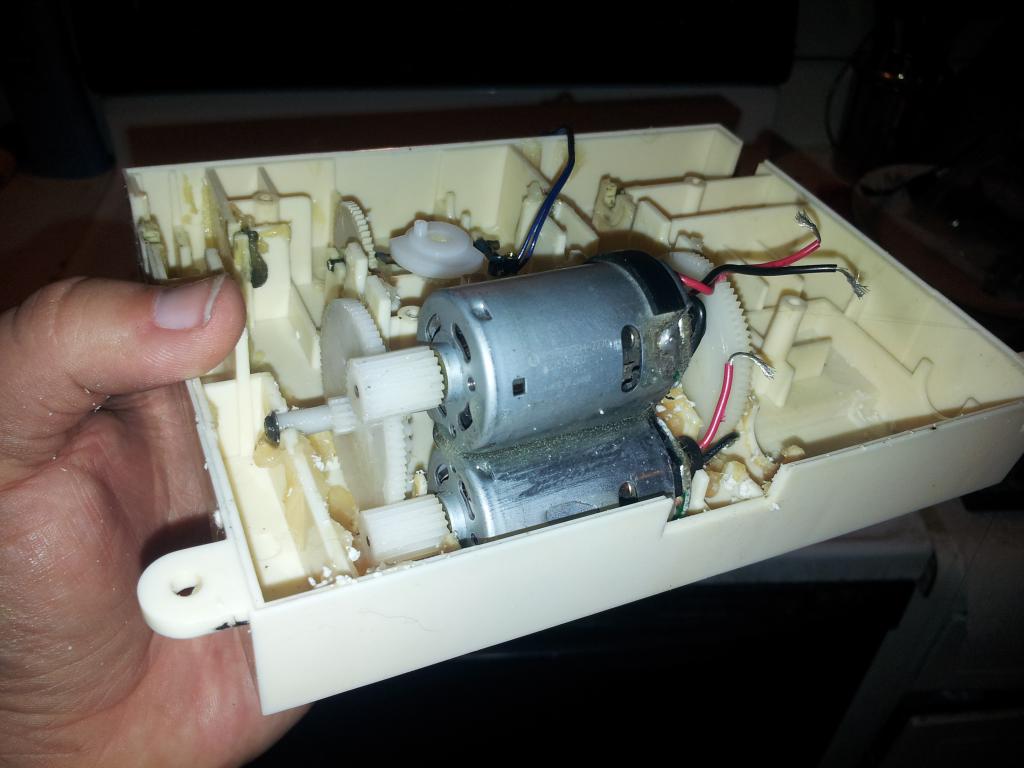
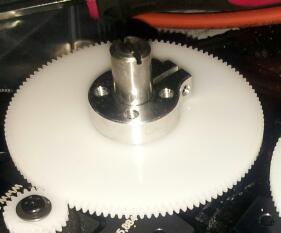
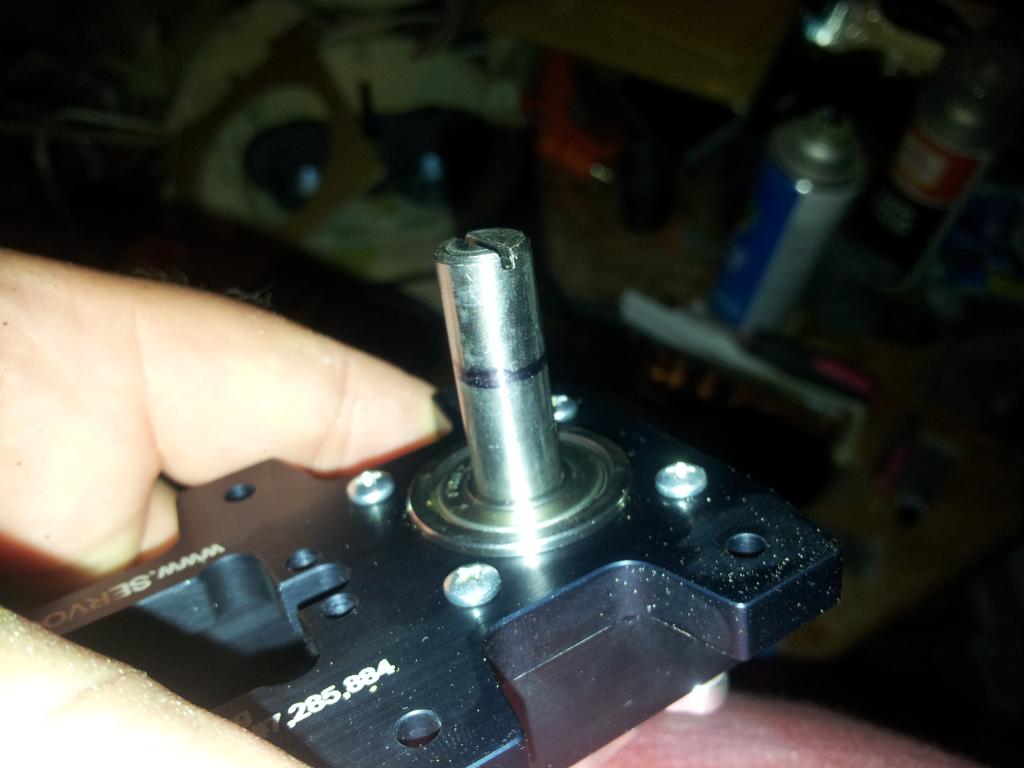
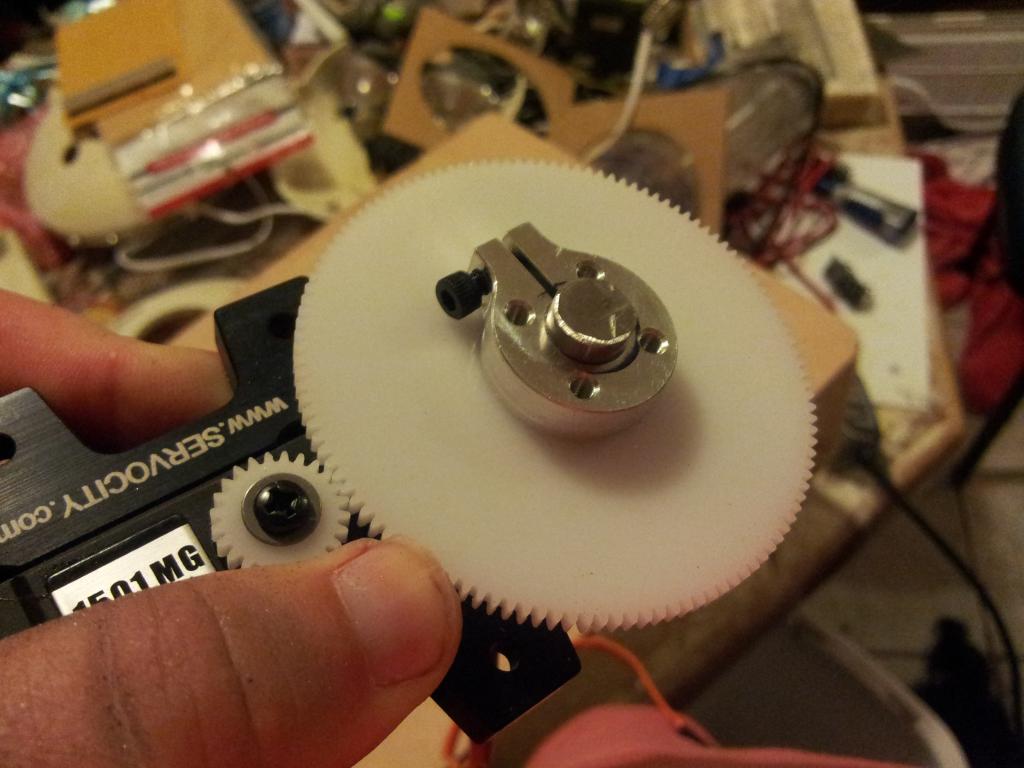
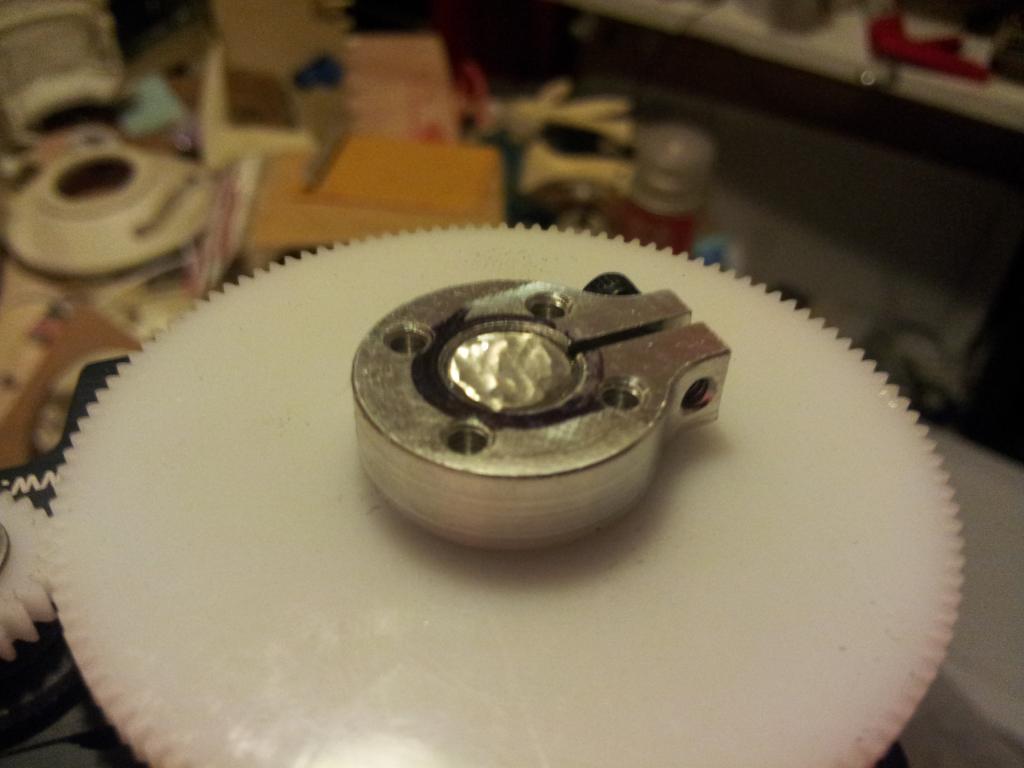
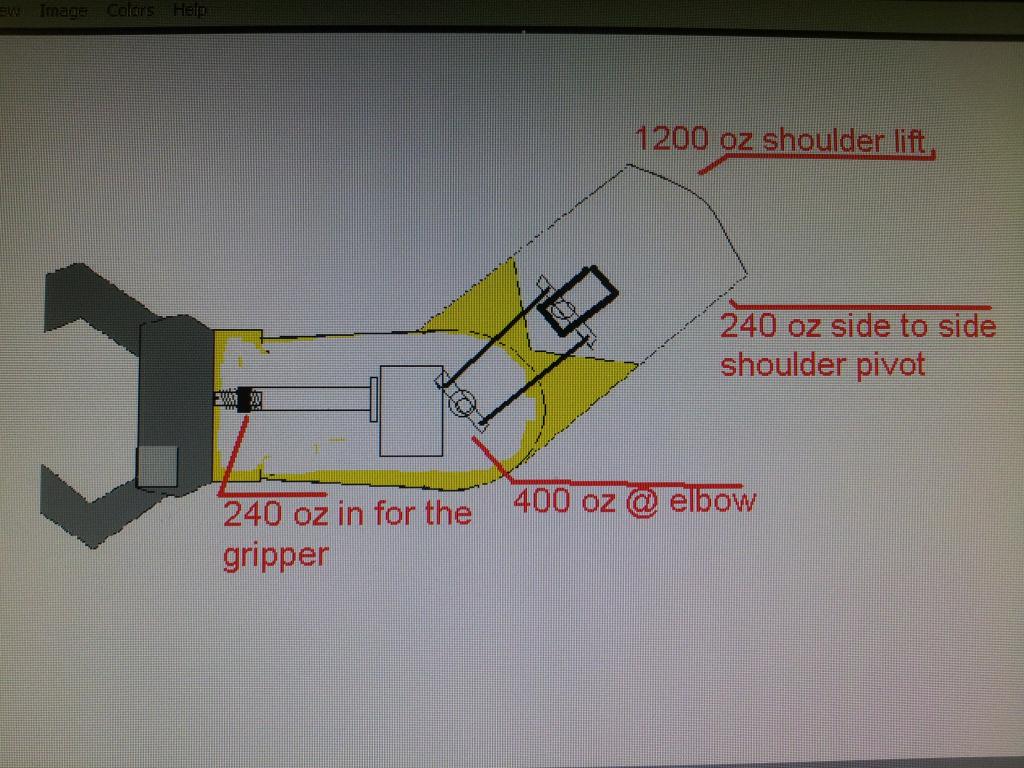
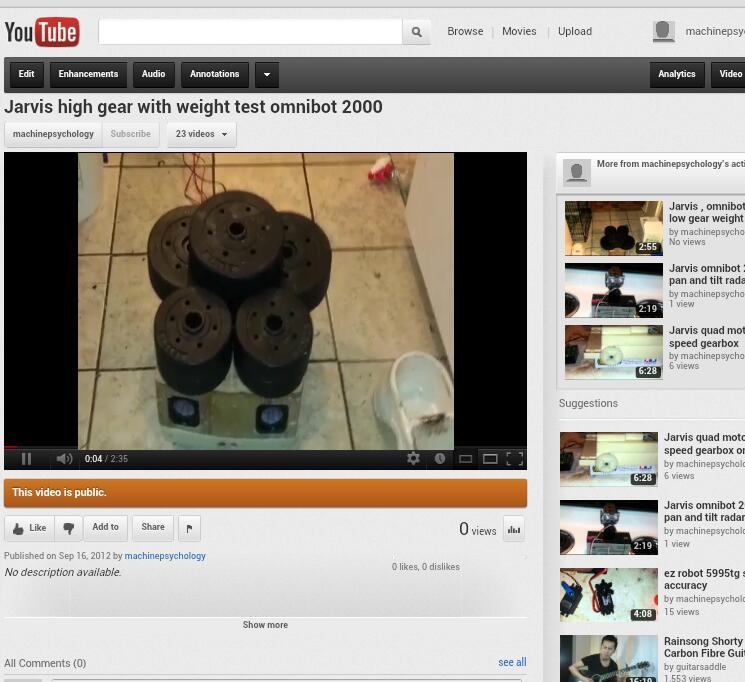
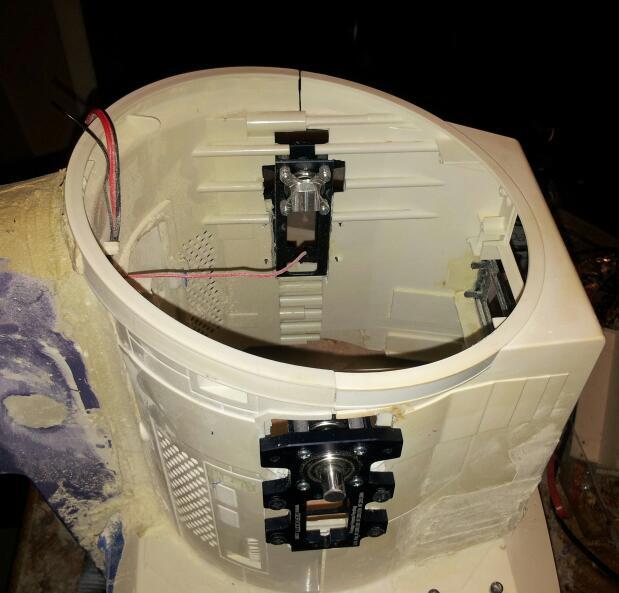
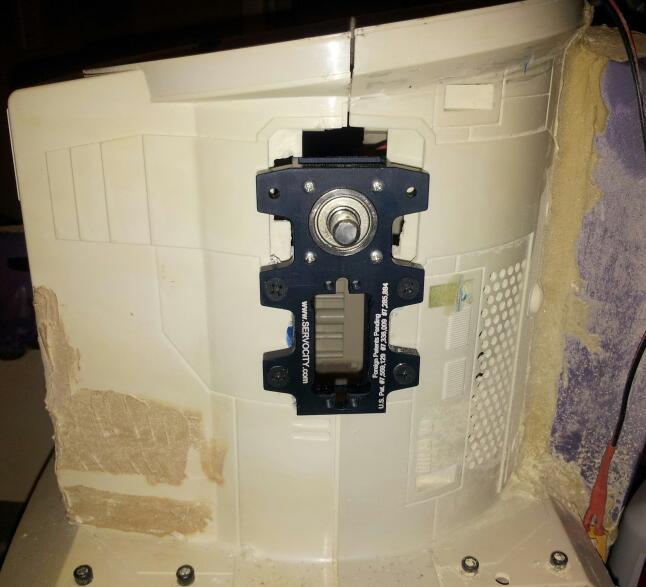
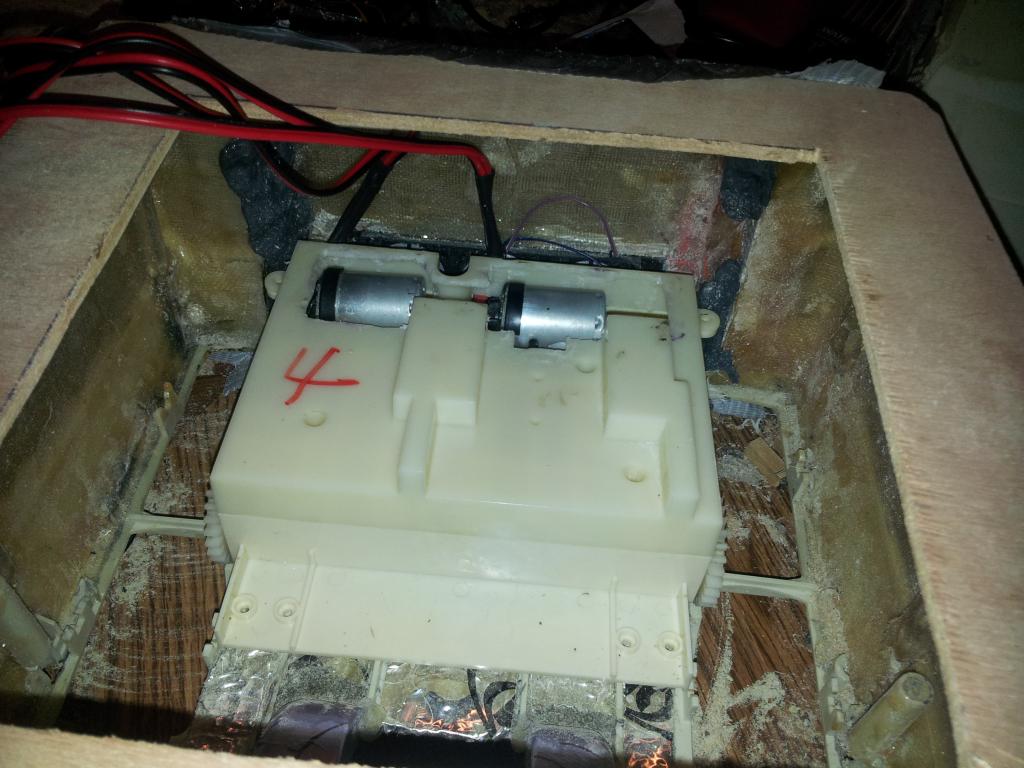
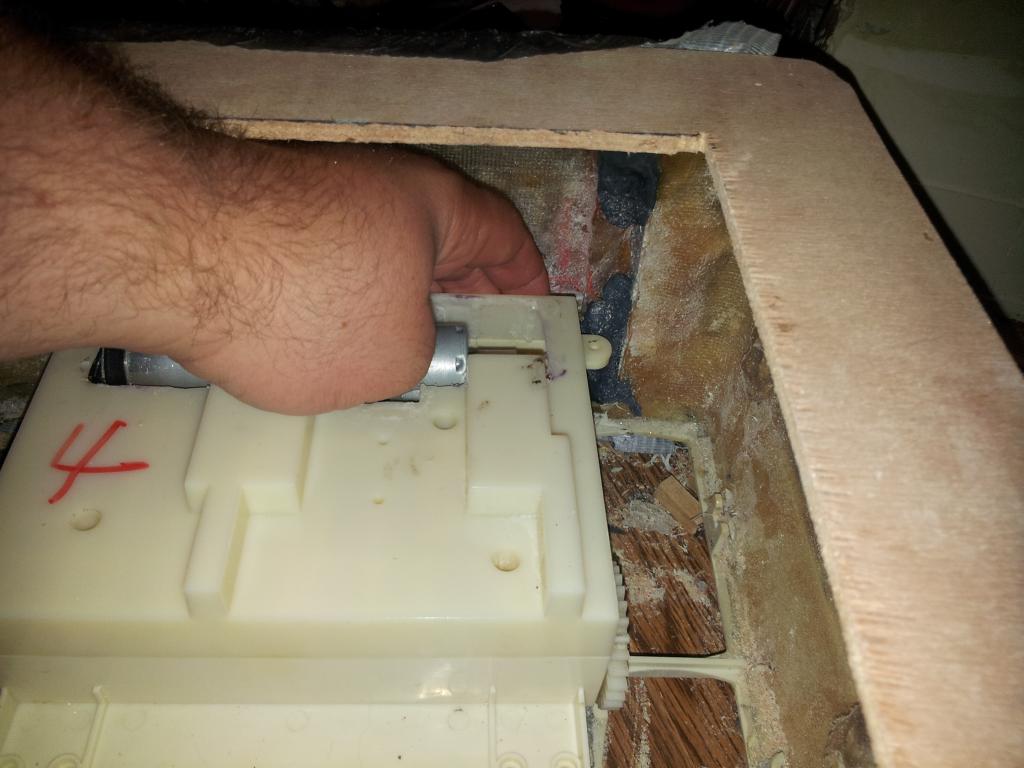
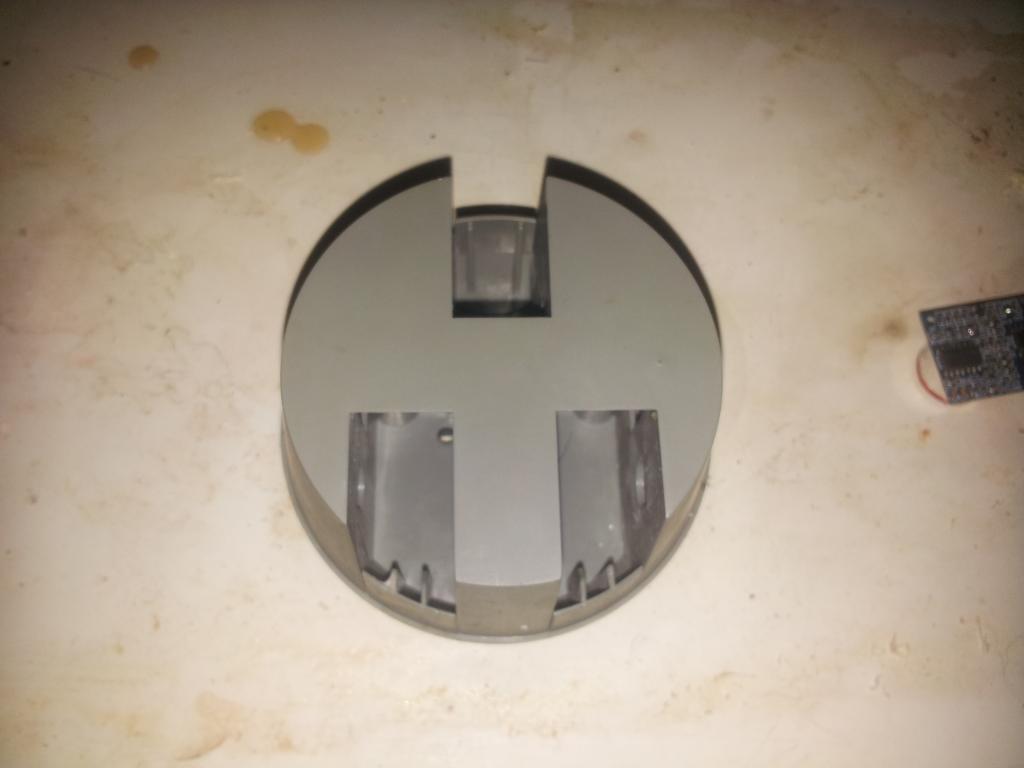
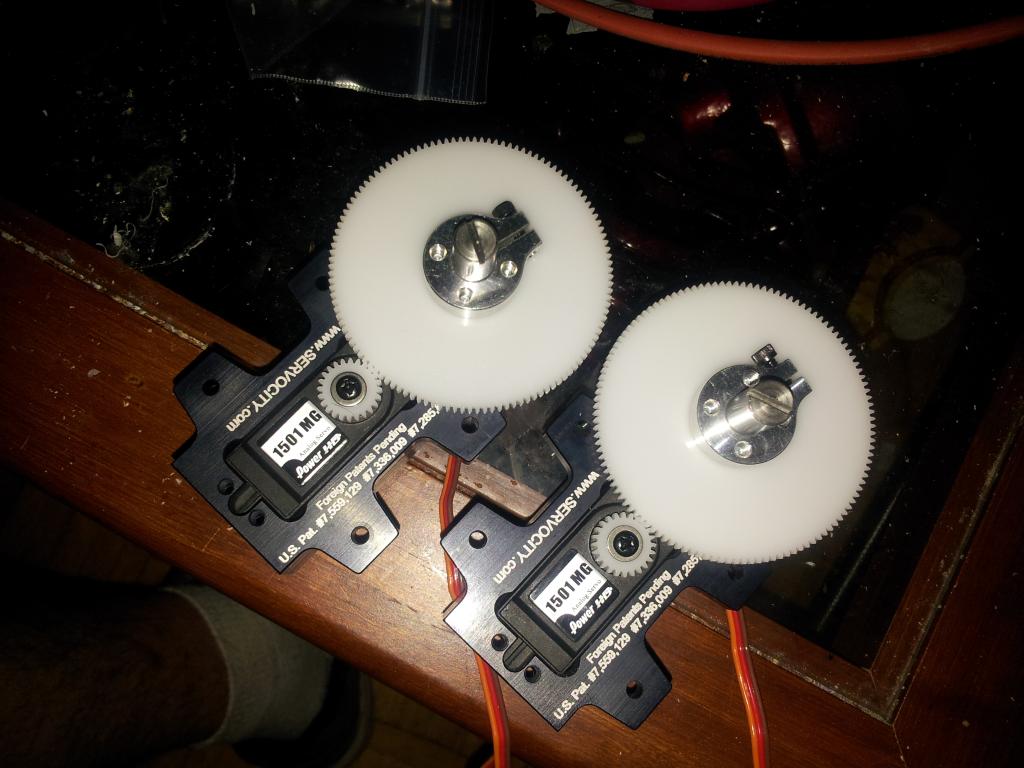
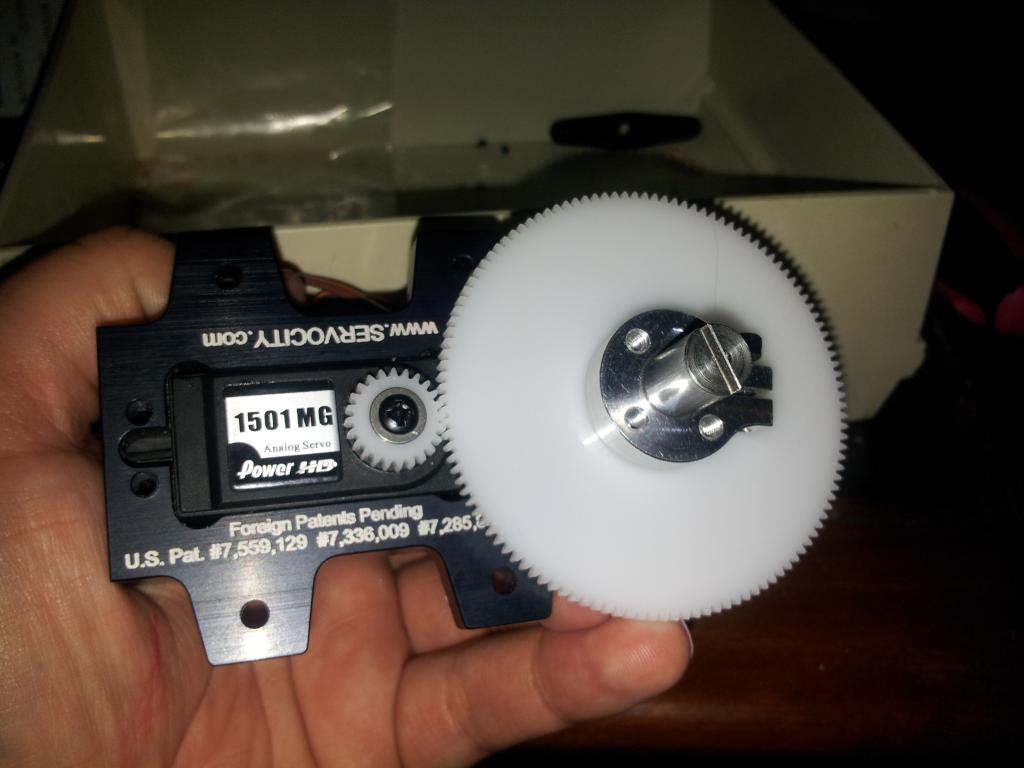
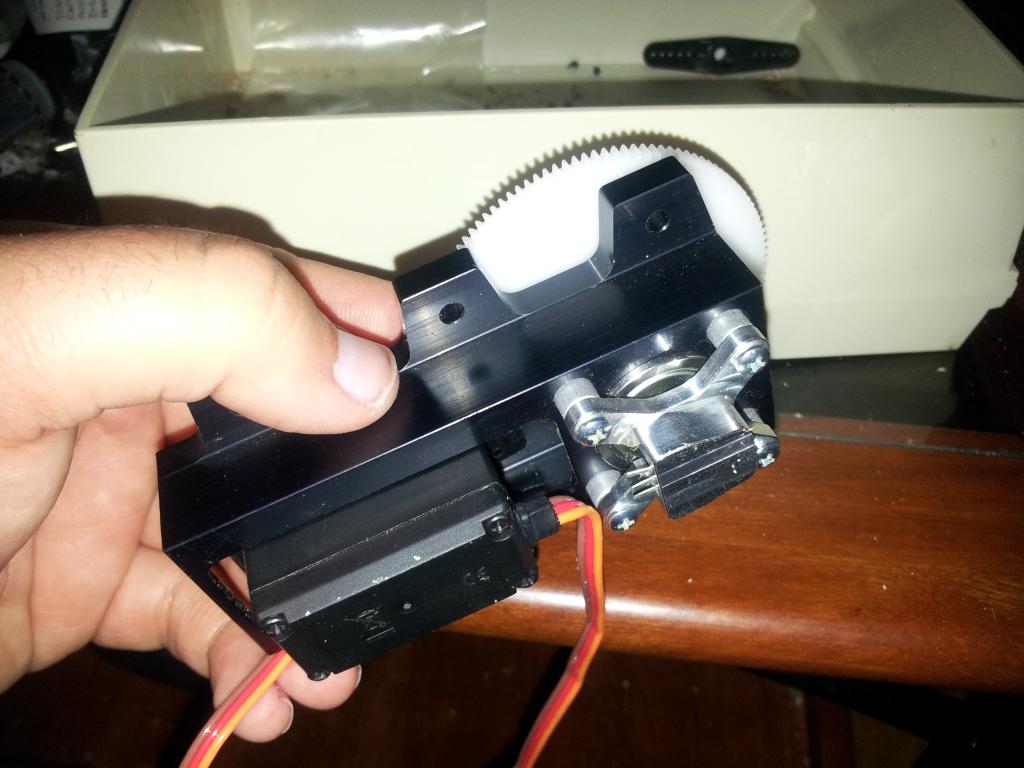
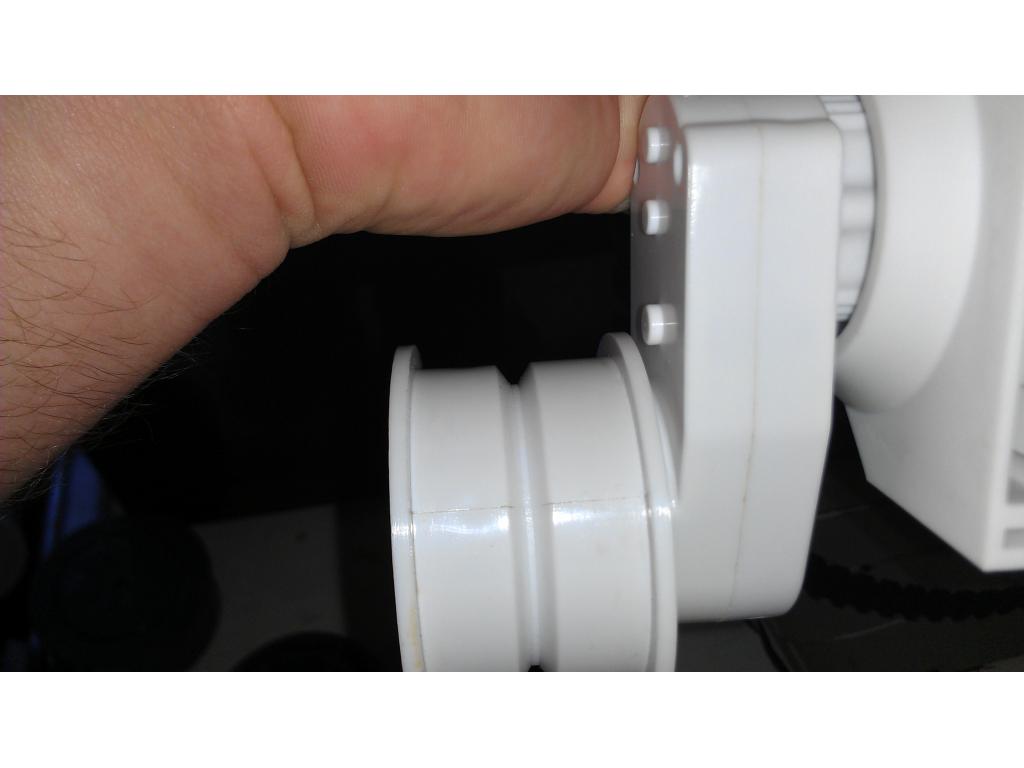
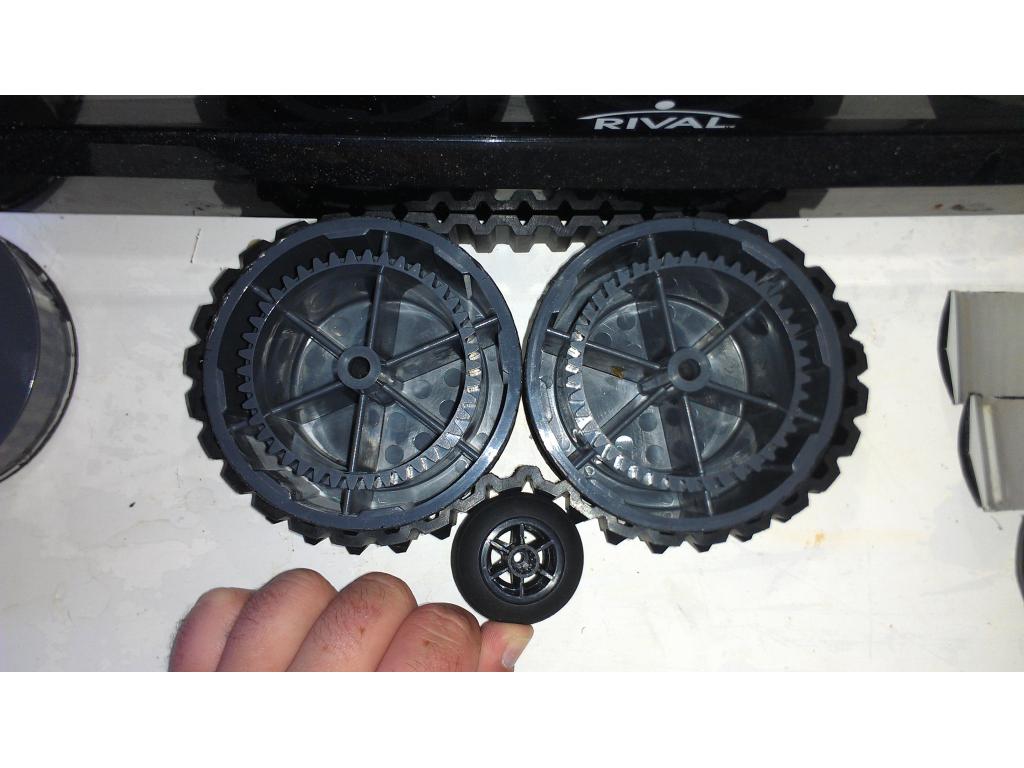
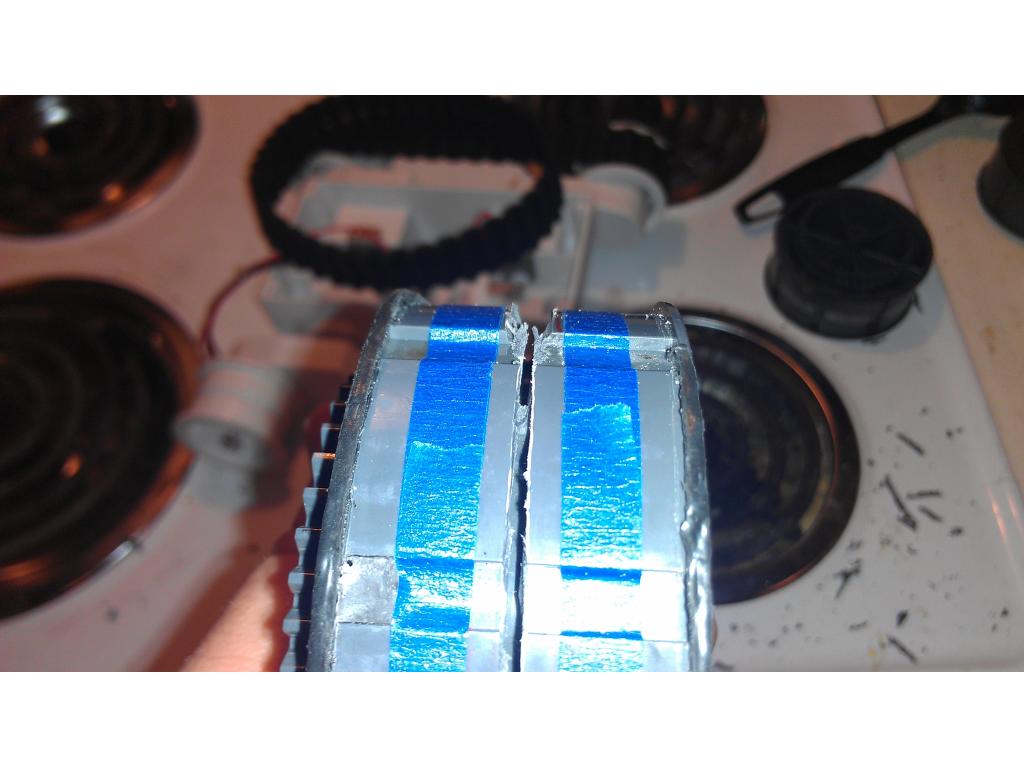
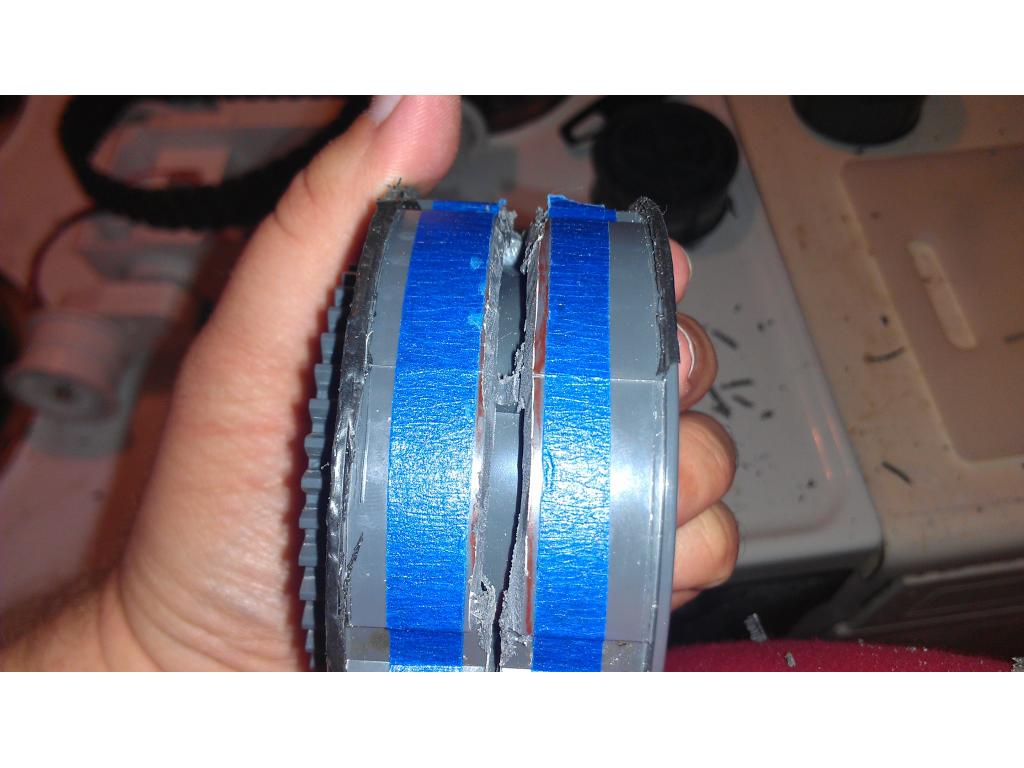
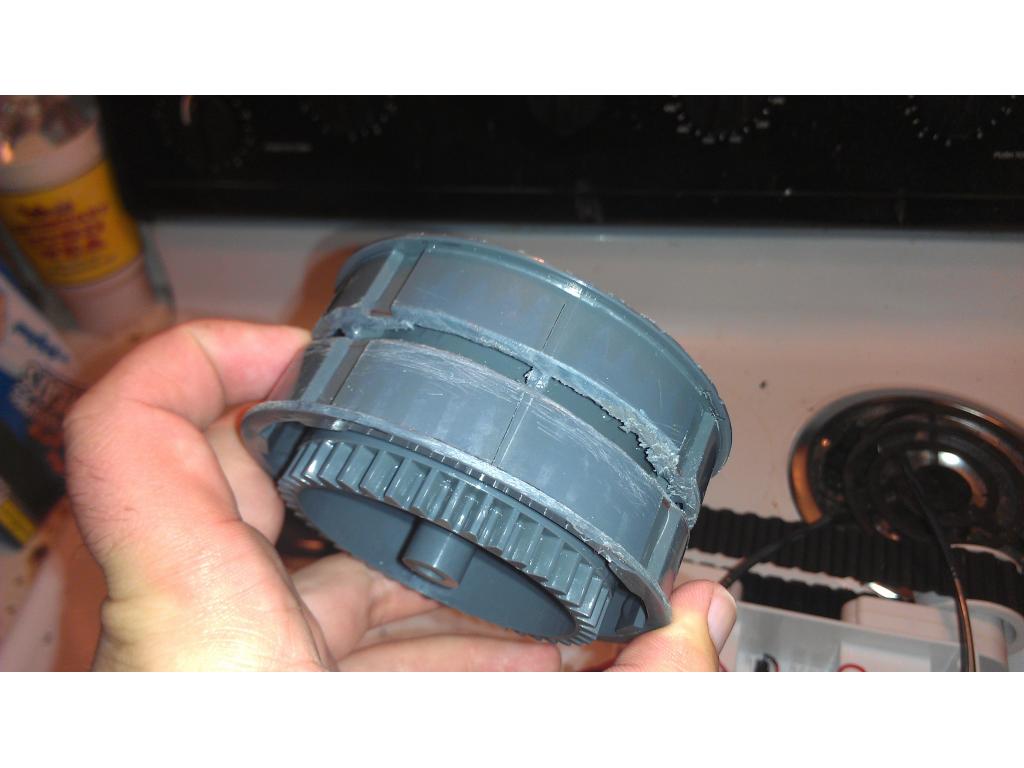
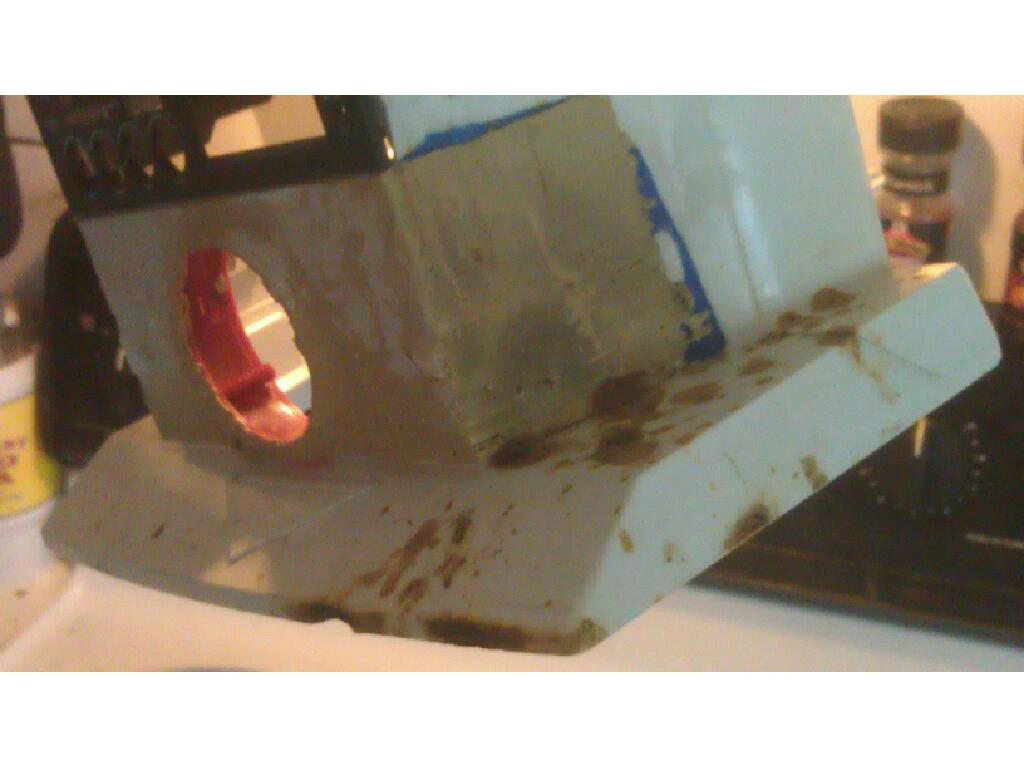
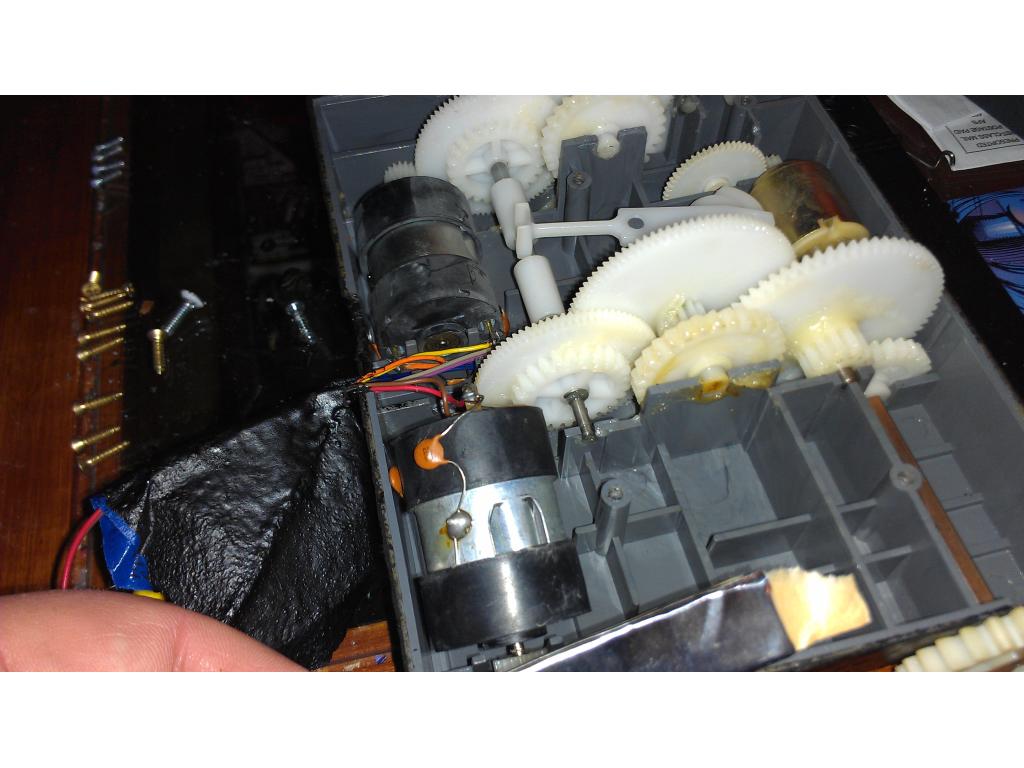
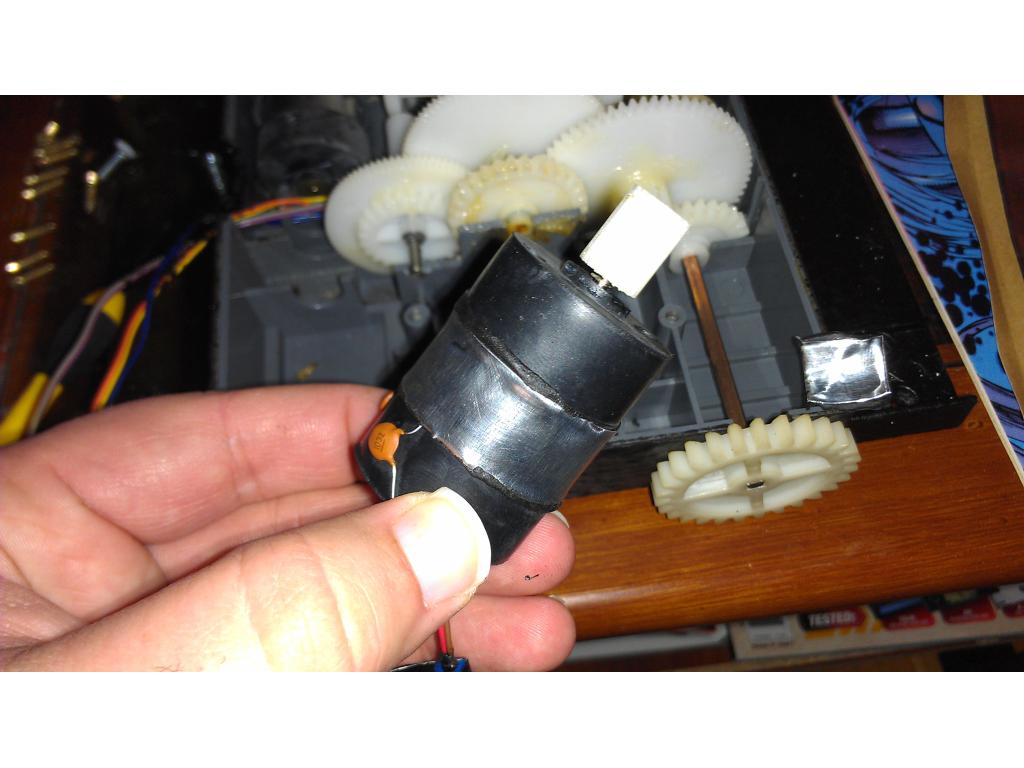
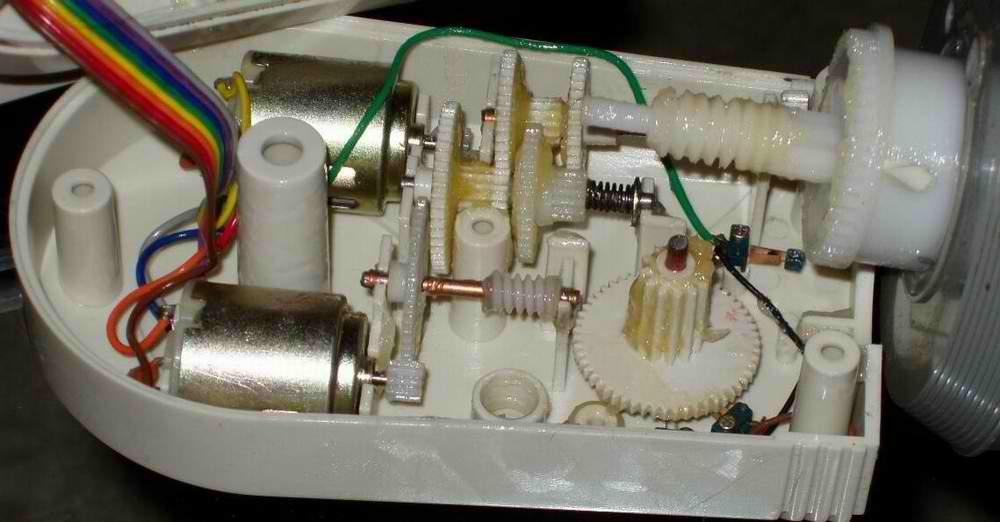
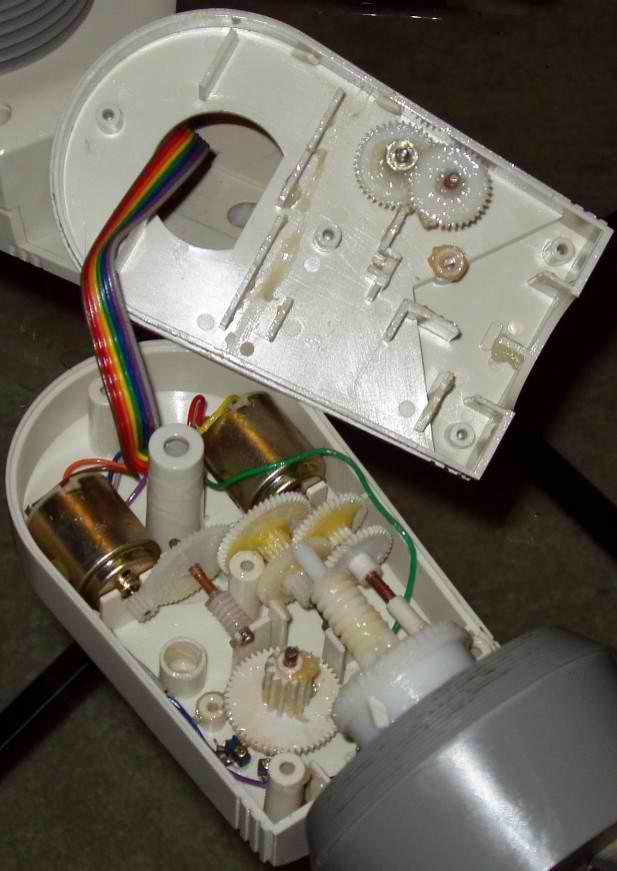
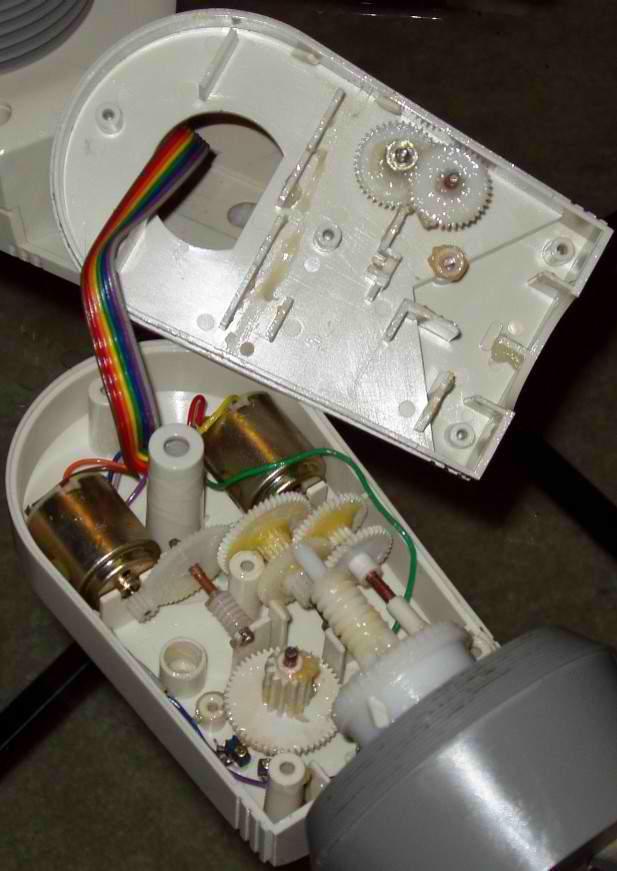
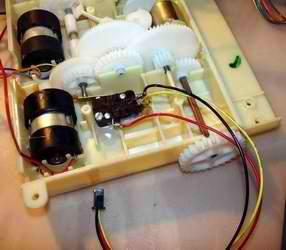
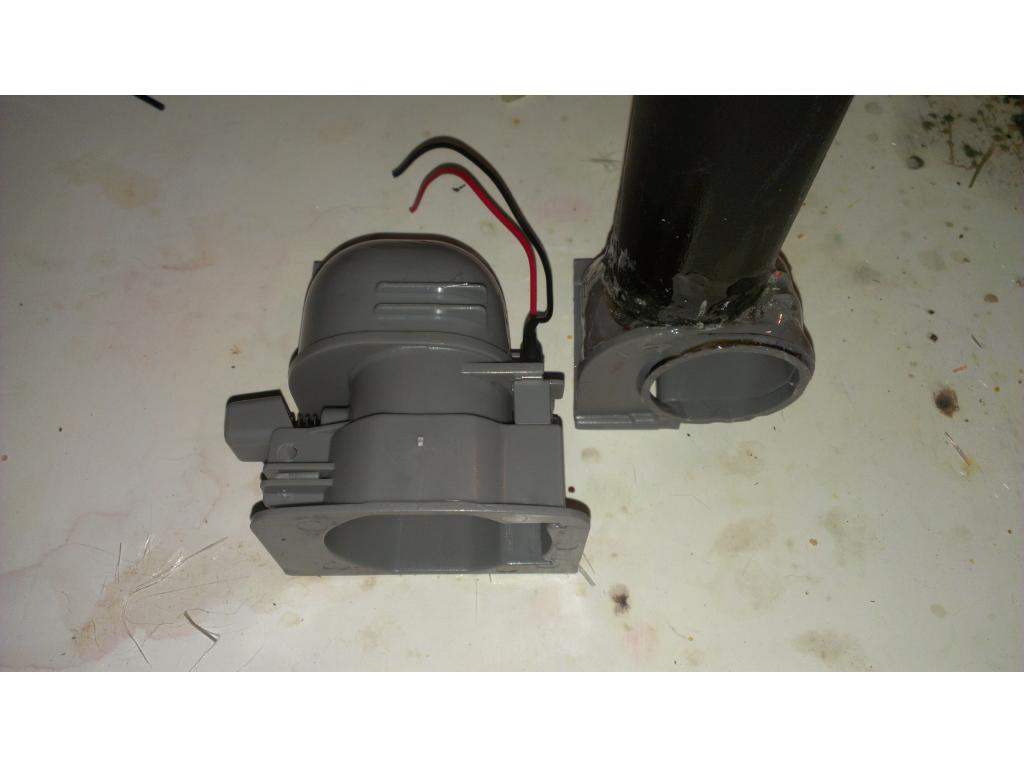
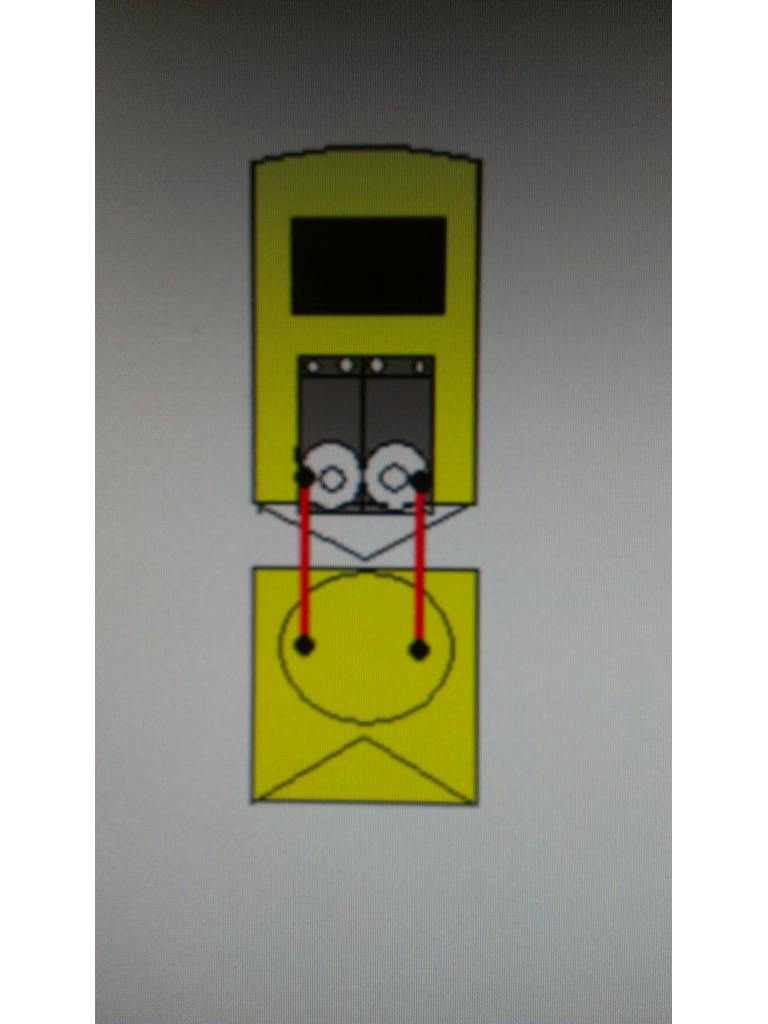
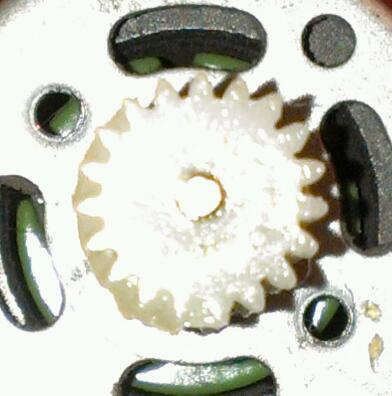
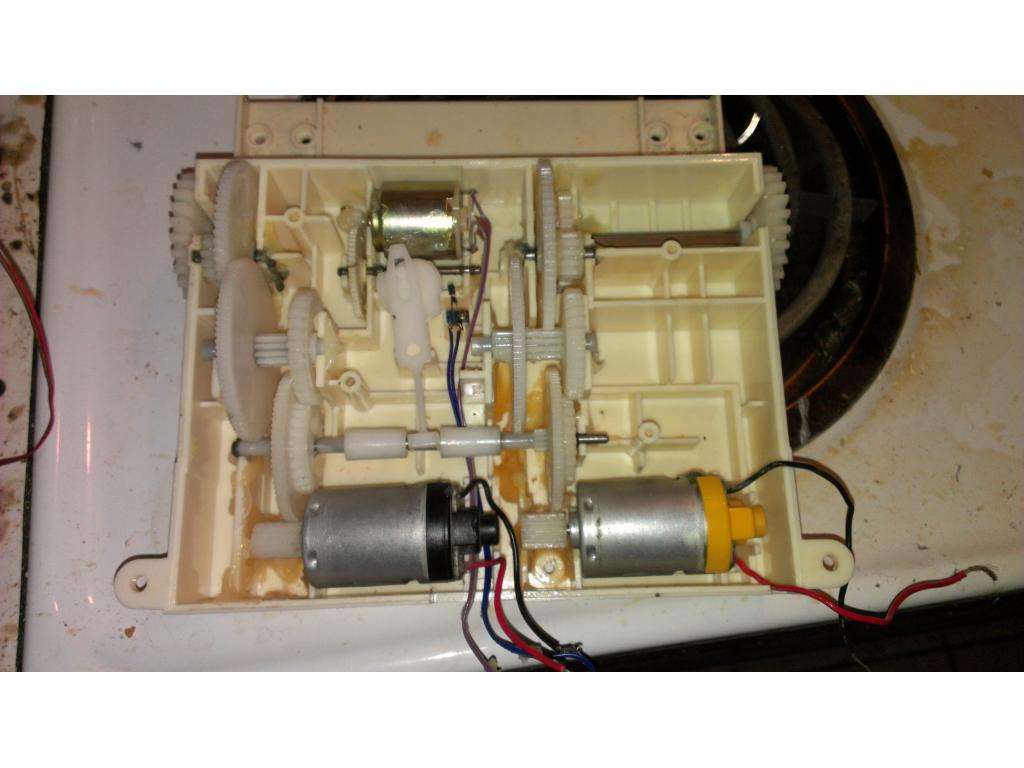
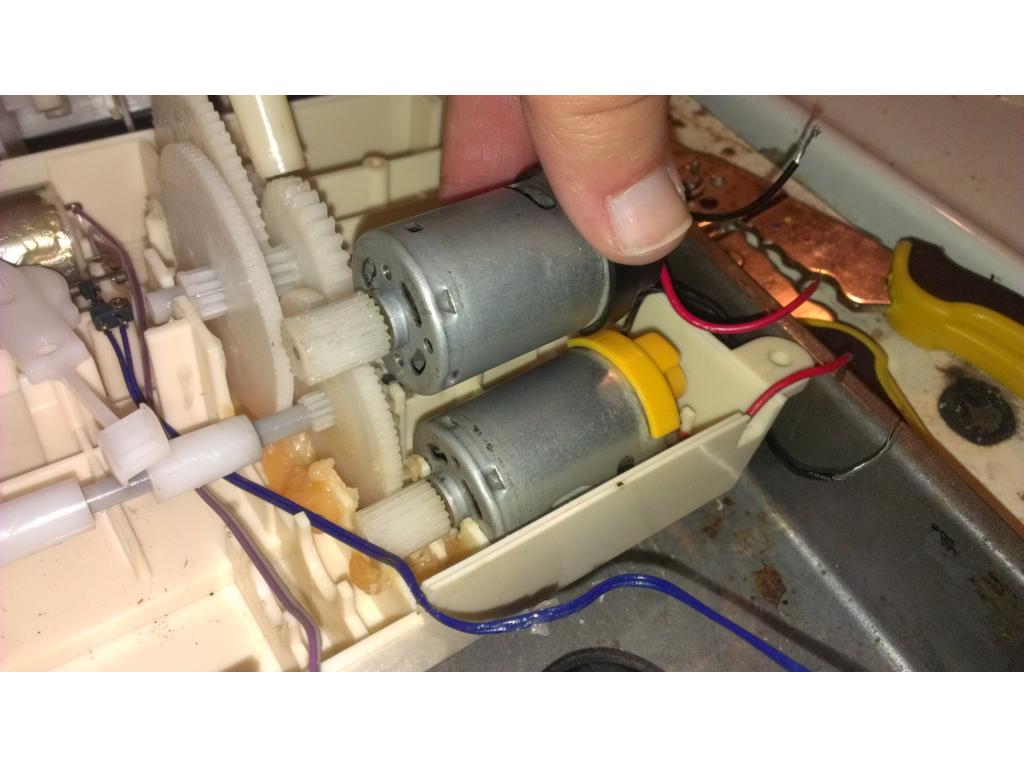
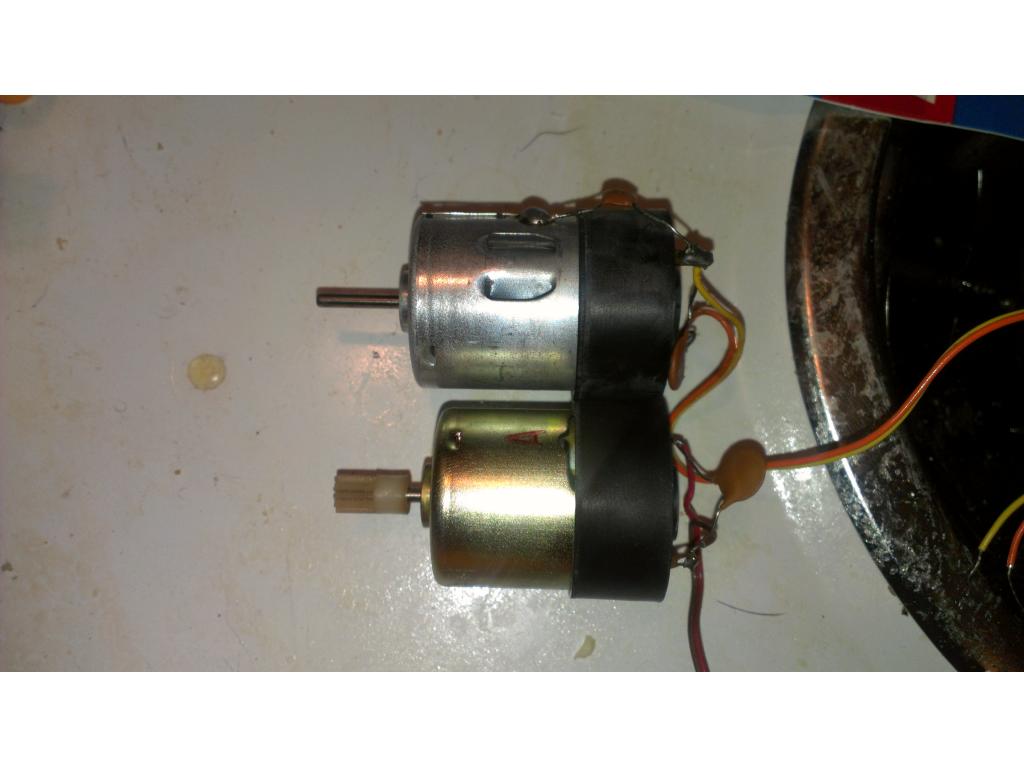
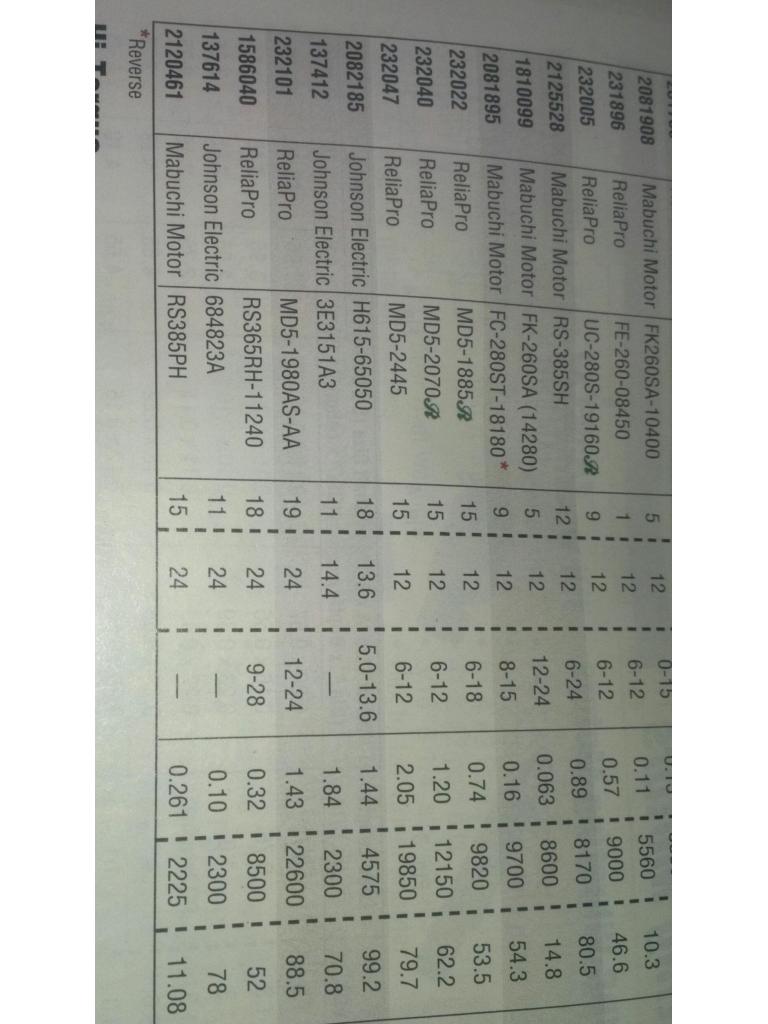
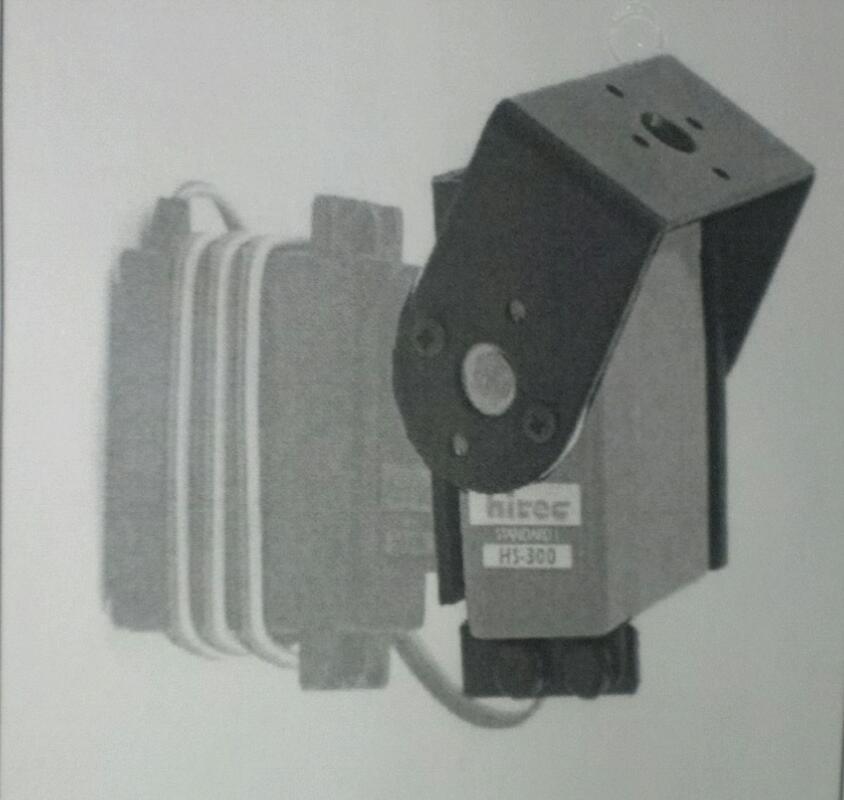
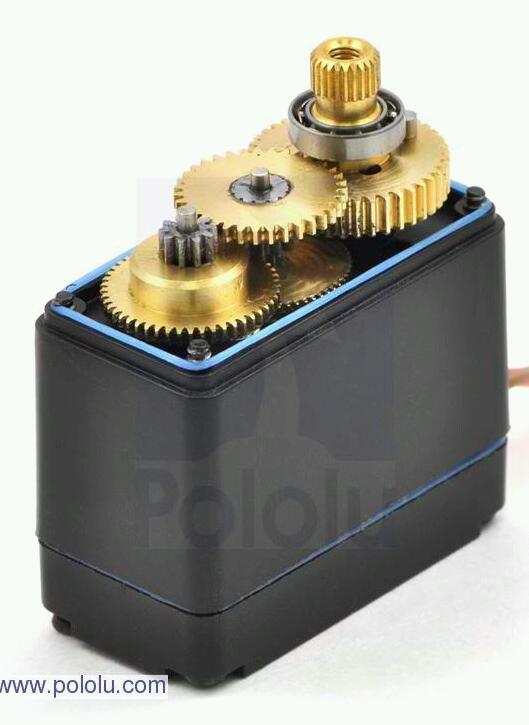
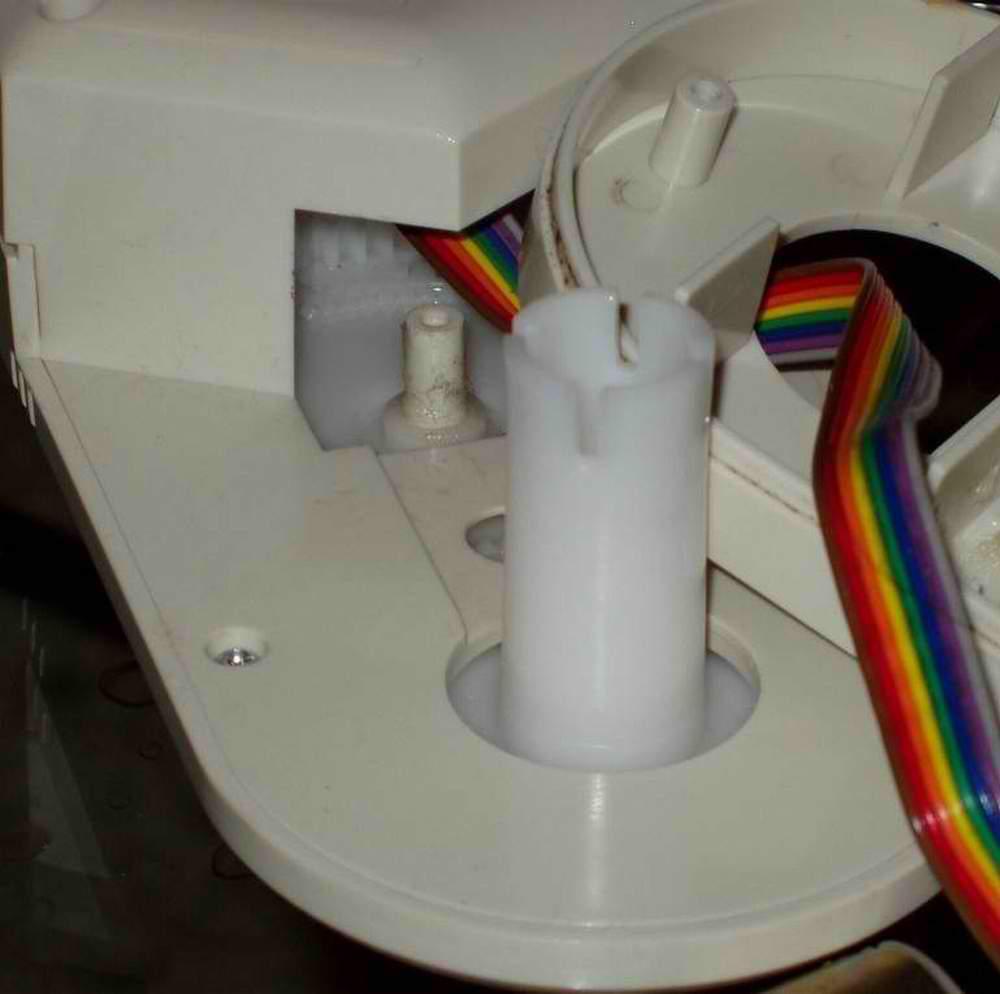
Geartrain modding - robotmaker sent me two motors that.have more torque than my stock ones , if I could get ahold of a second gearbox for a 2000 I could do a "quad motor" drive I just need the extra gears. I'm confident that I can upgrade it to smoothly move my heavy bot.
For the most.part the motors can fit with some small modifications but I really need to see if I can get ahold of at least 2 more opinions that go on the motors so I can do quad motor setup , that would split the torque between two motors and I believe would easily move my 60 pound bot around.