
cE9s4PsOgeBQIORwjd5!~~60_1-634818020230156250.jpg)



Lupuc4g~~60_35-634706297915000000.jpg)


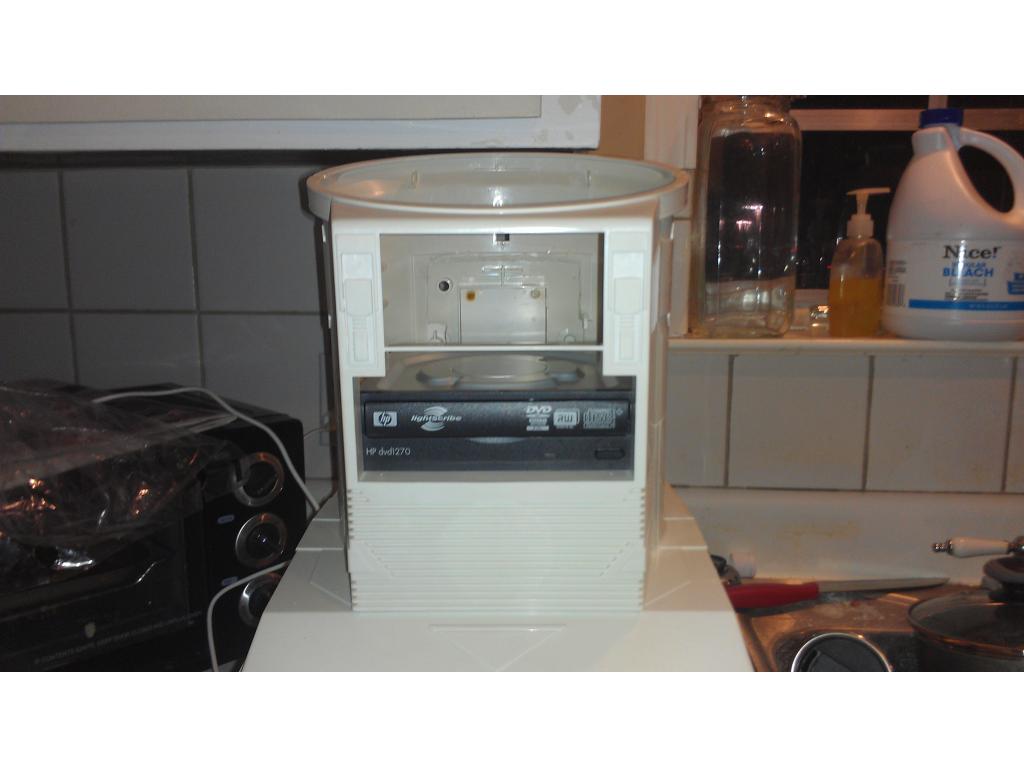
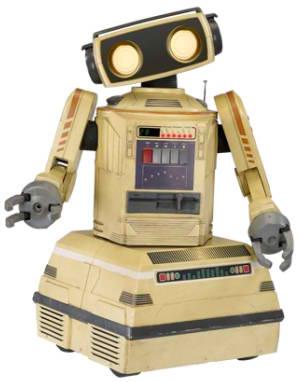
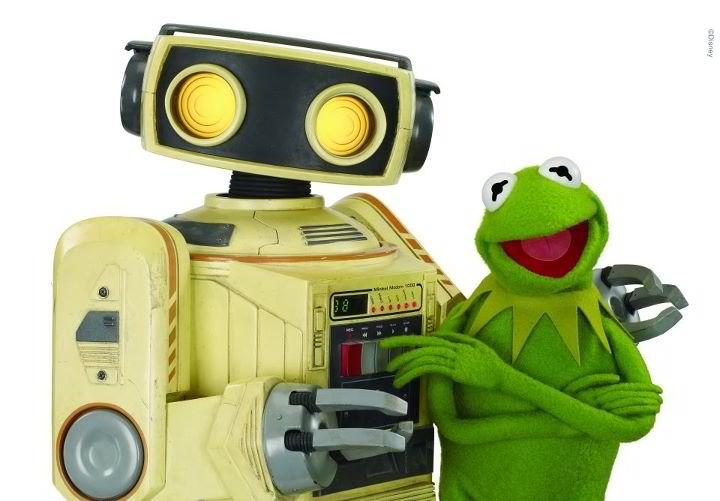
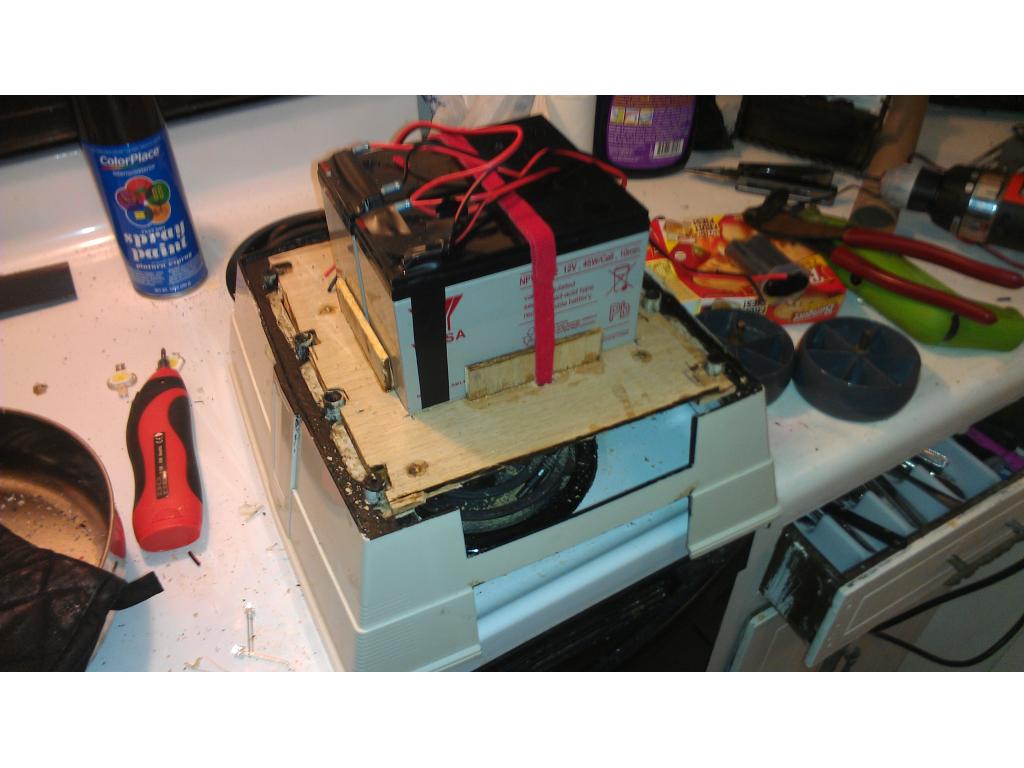

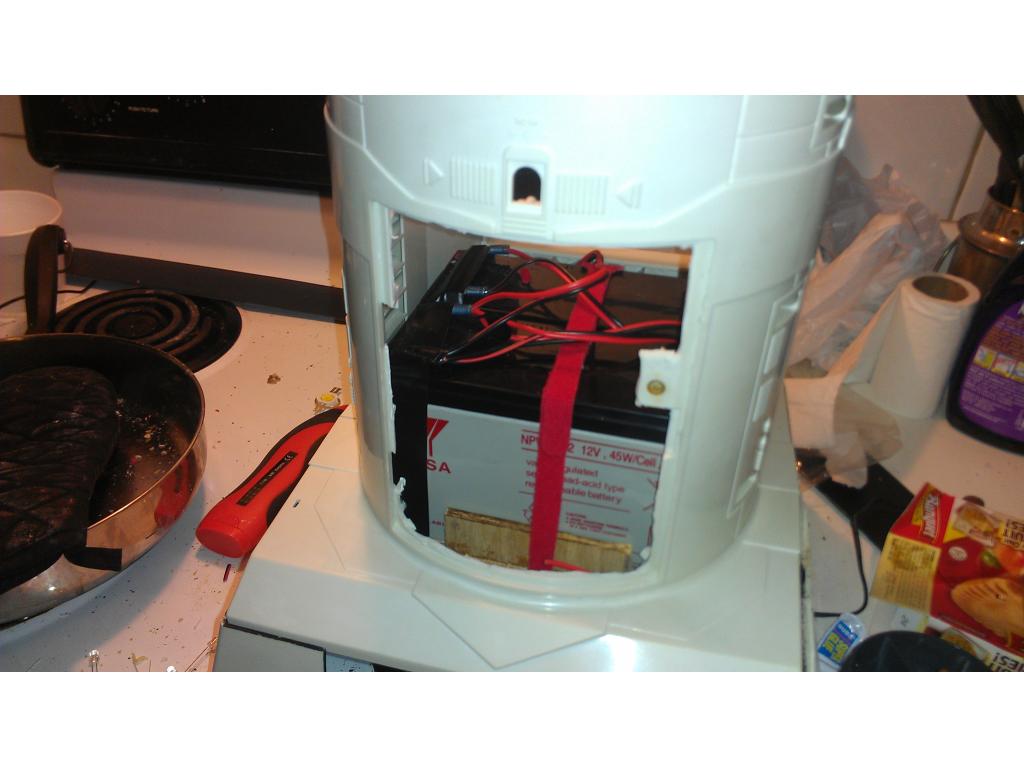
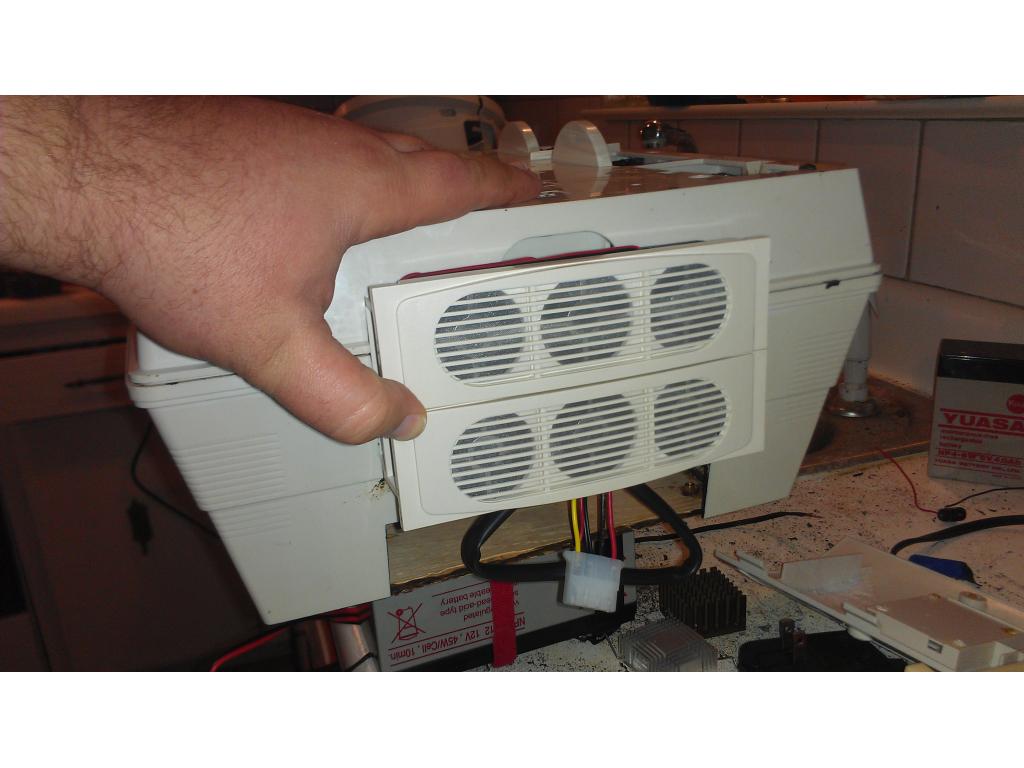
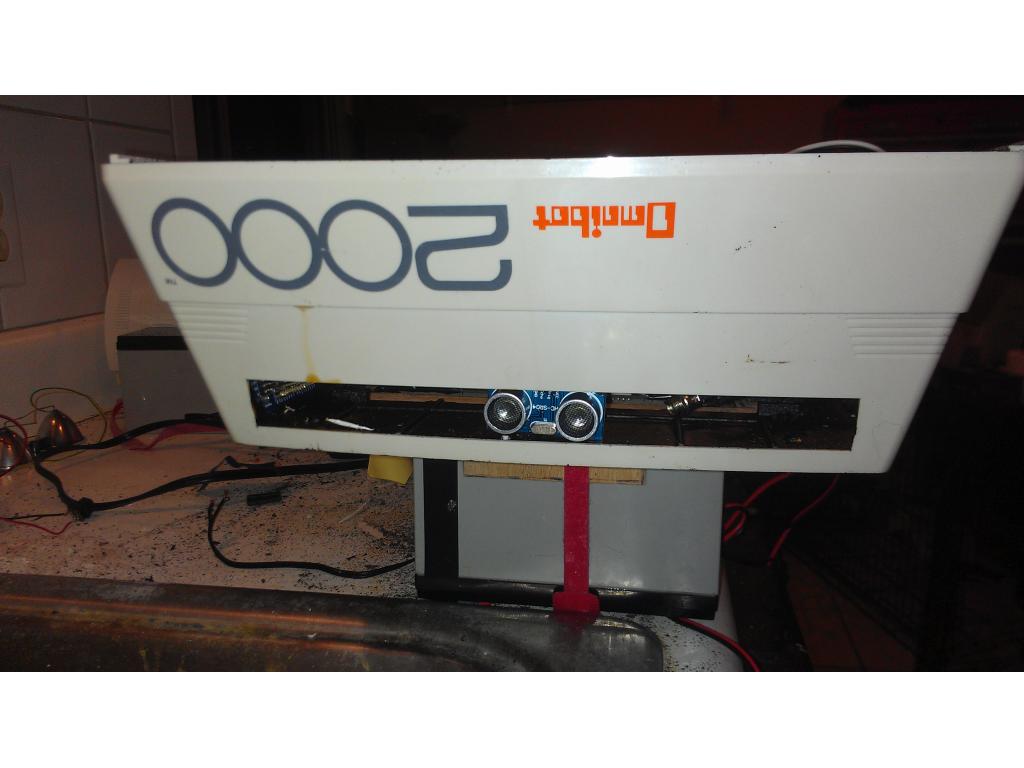
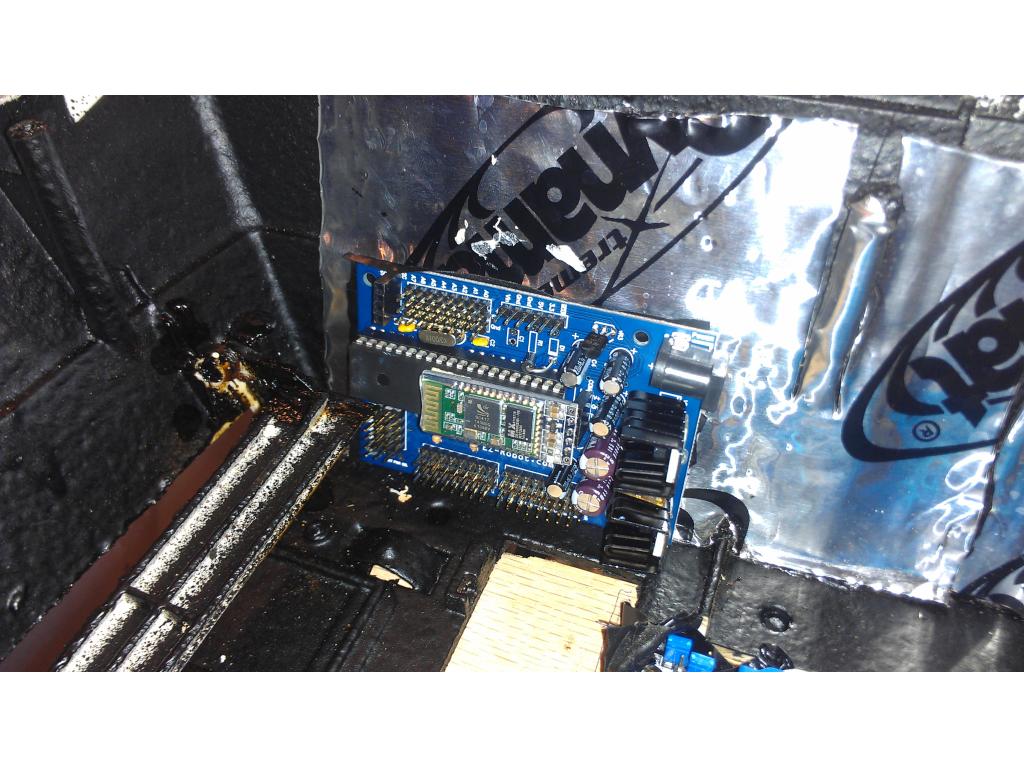
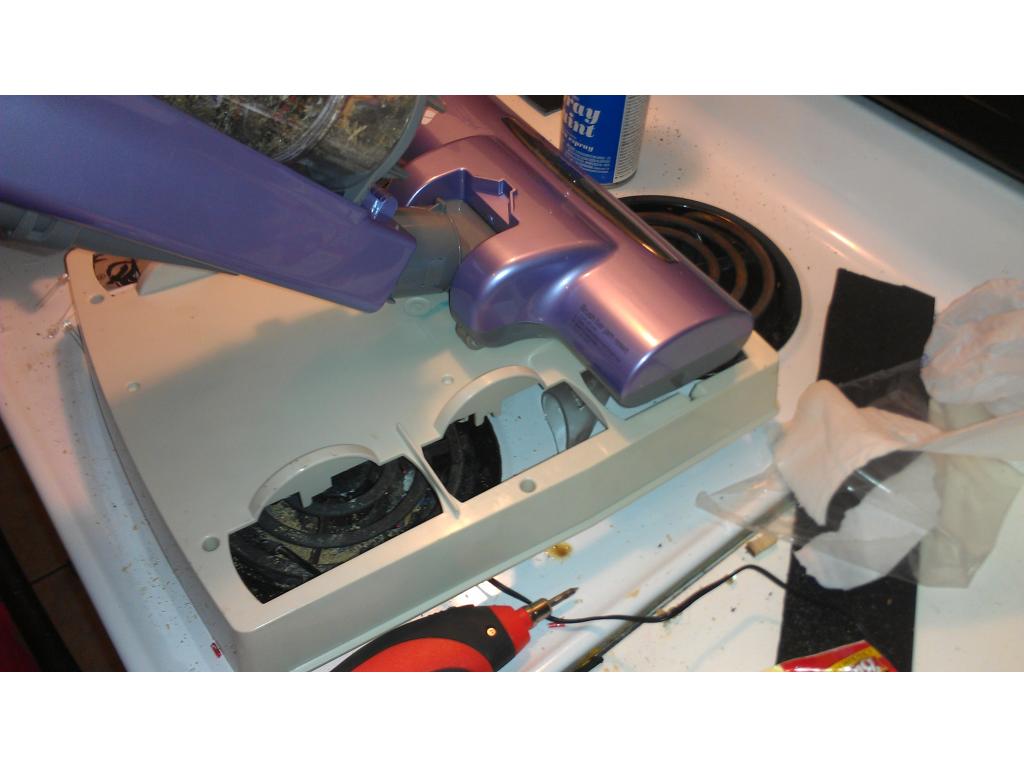

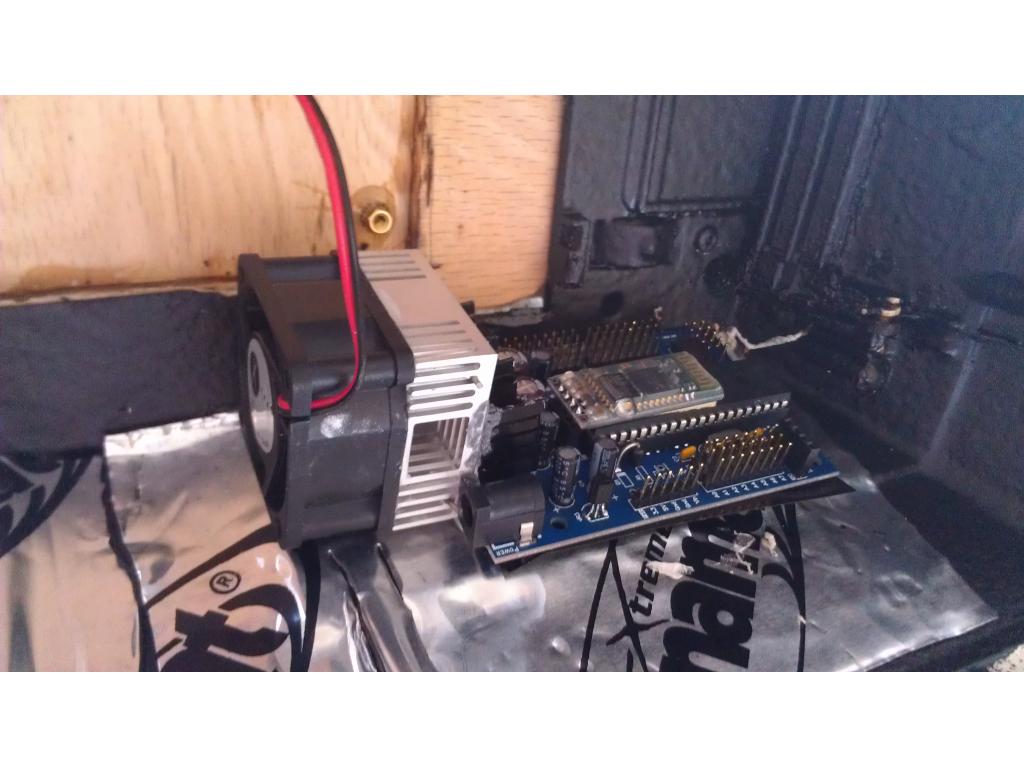
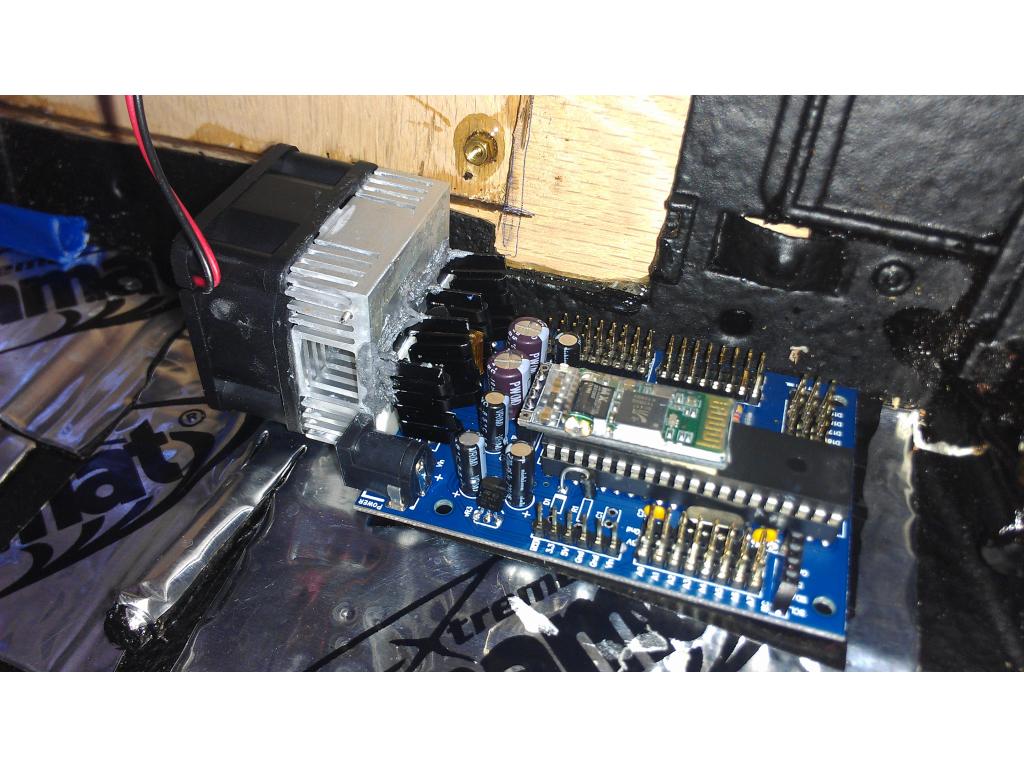

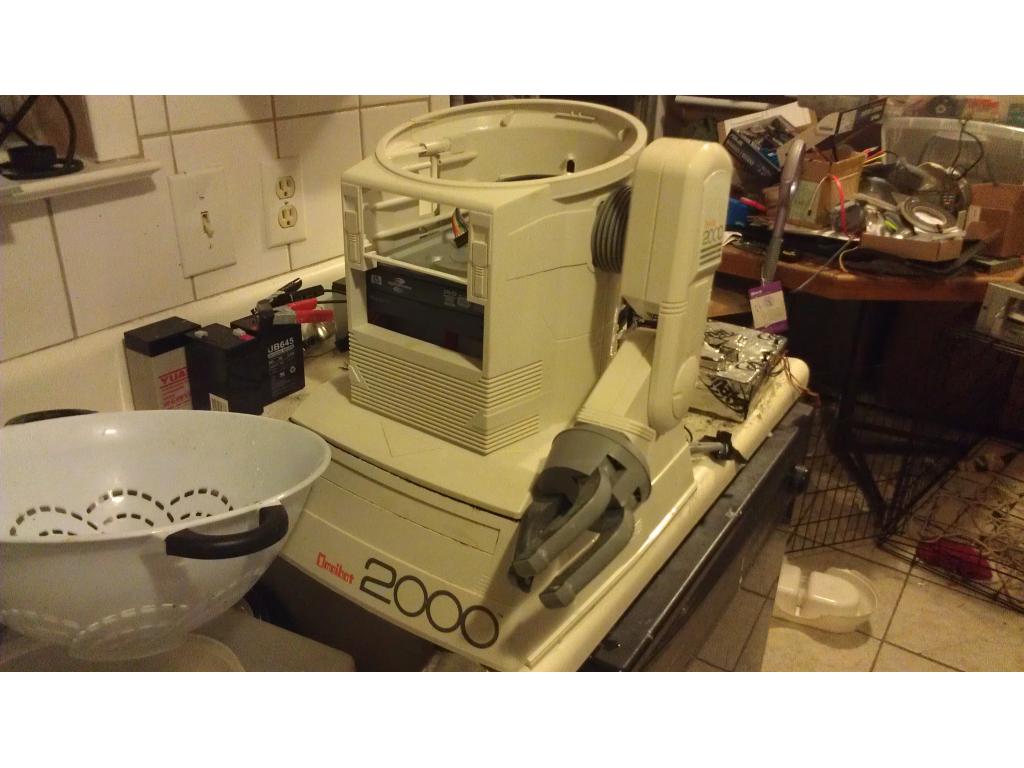
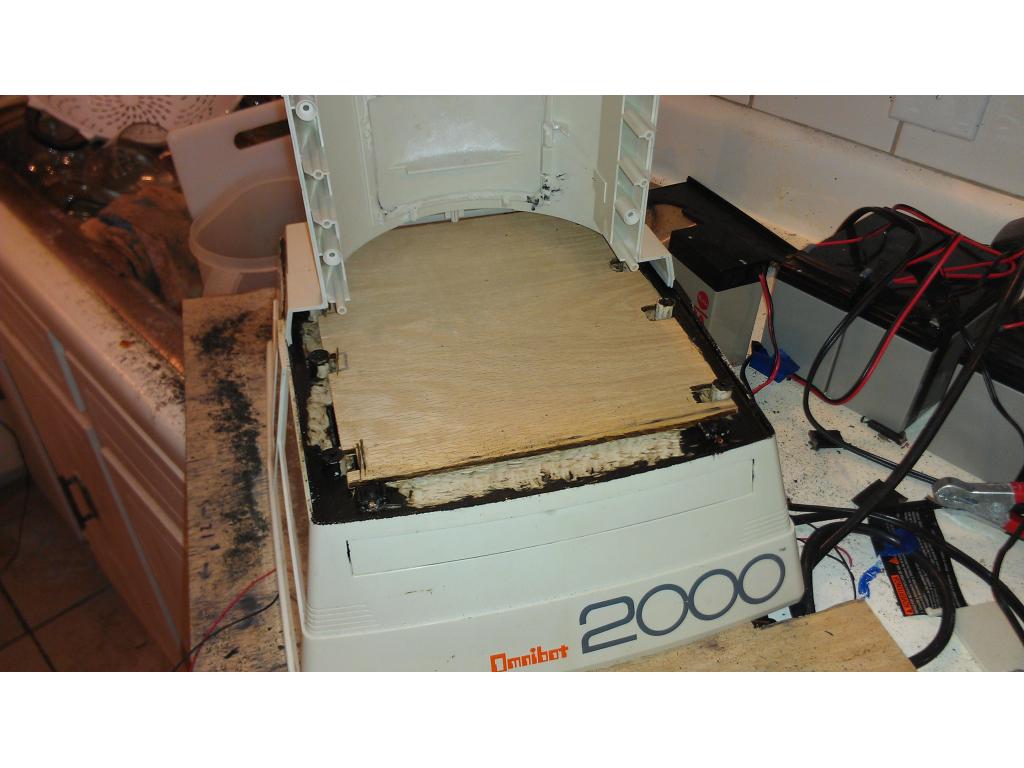
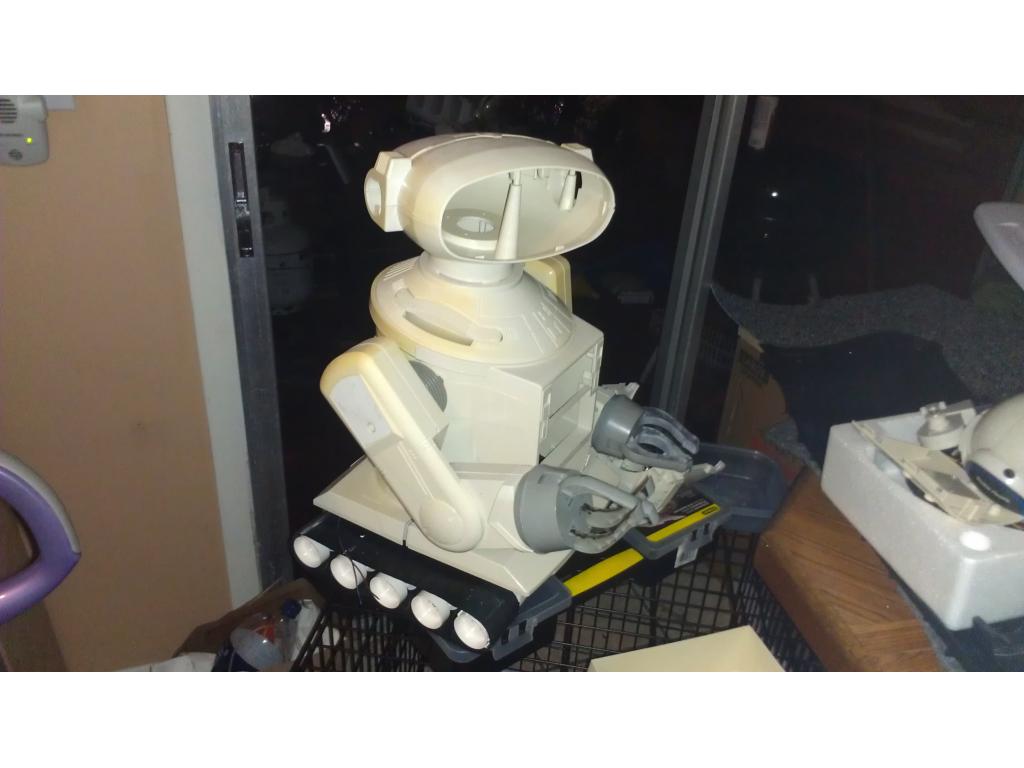
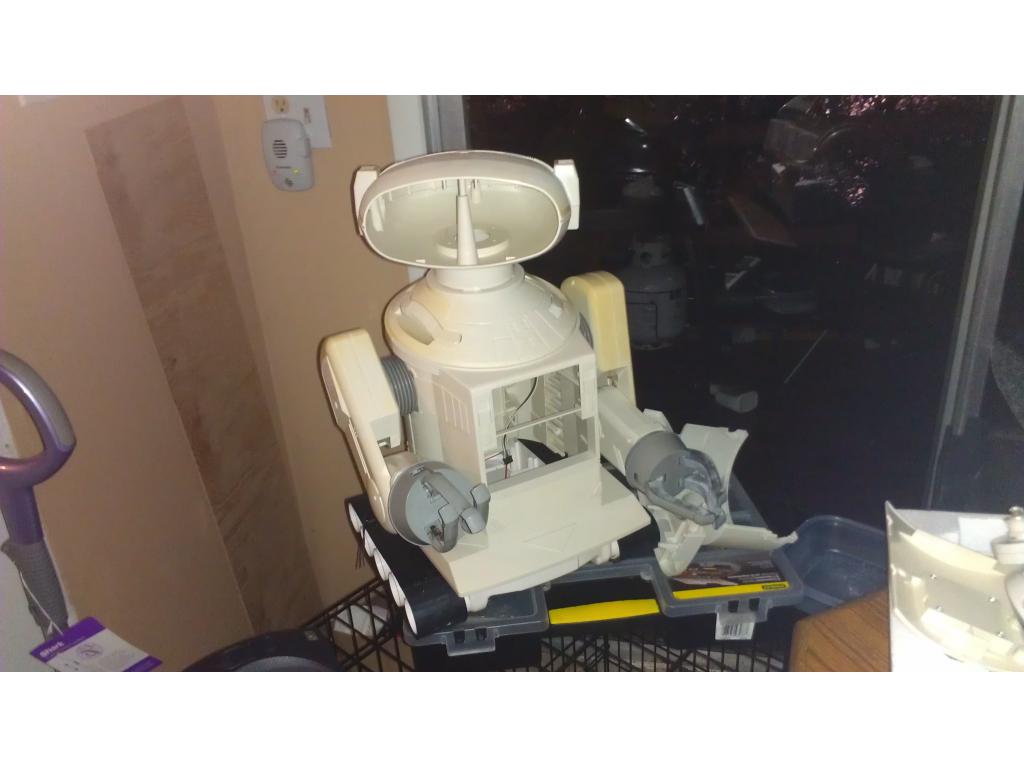
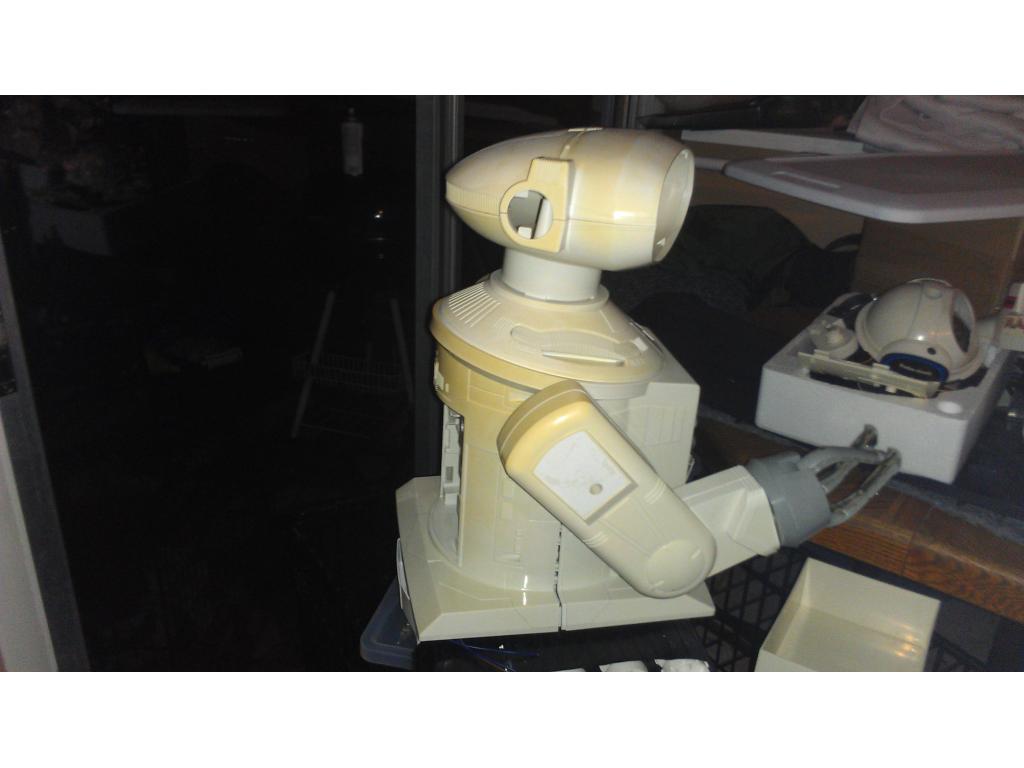
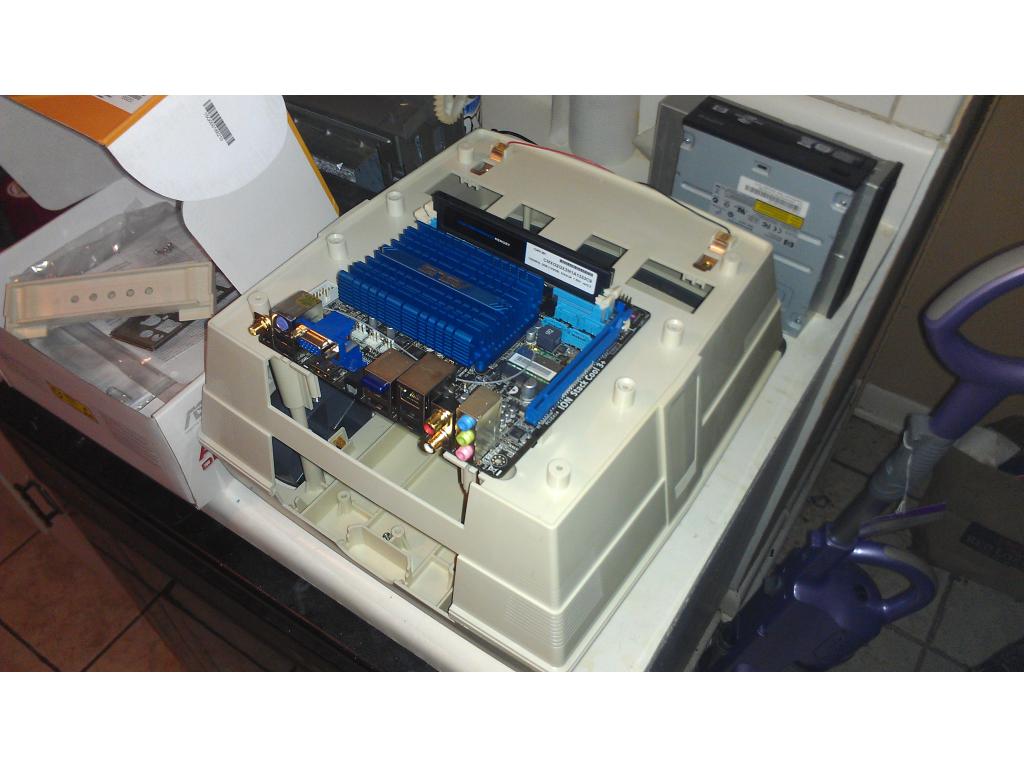
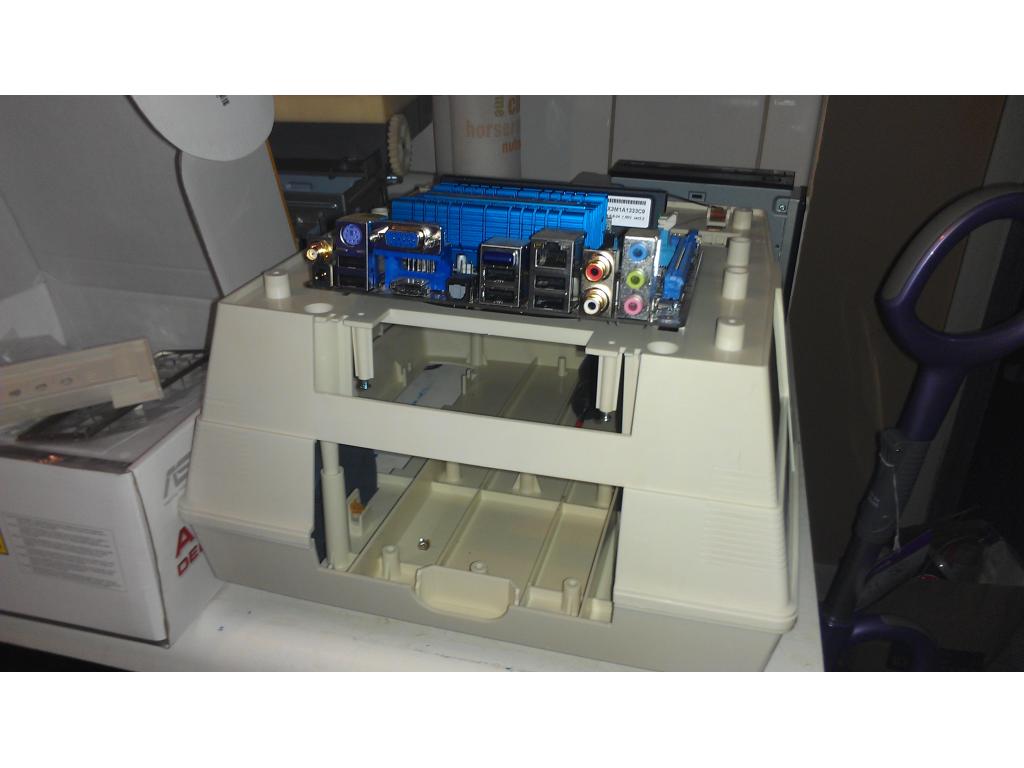
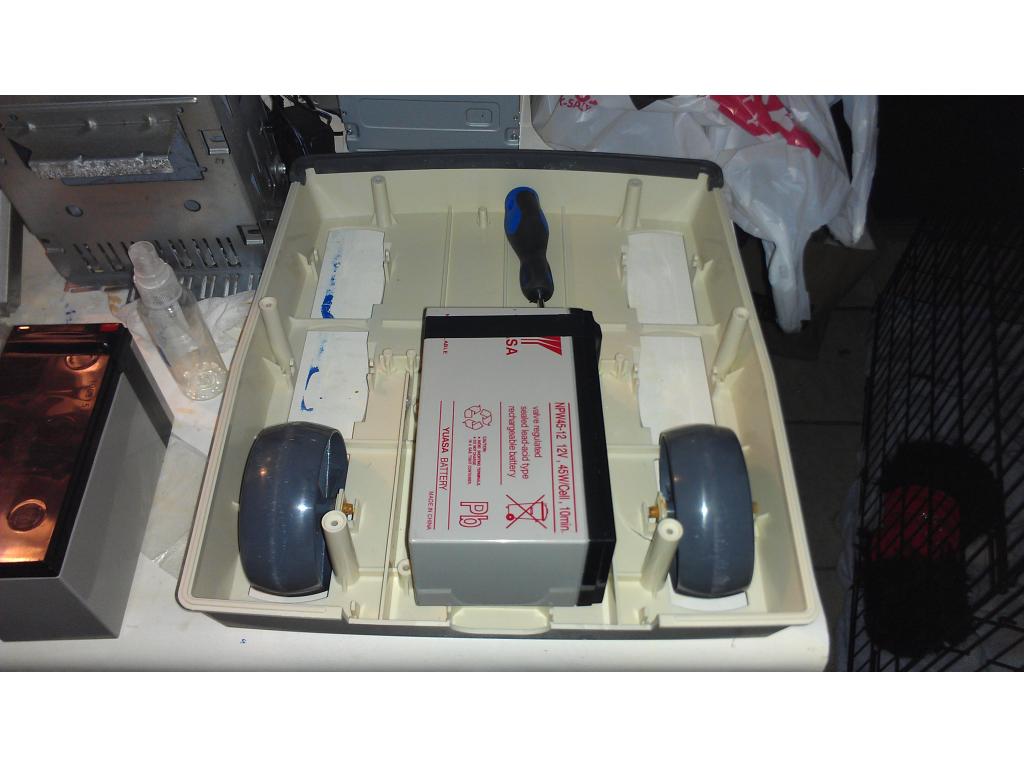
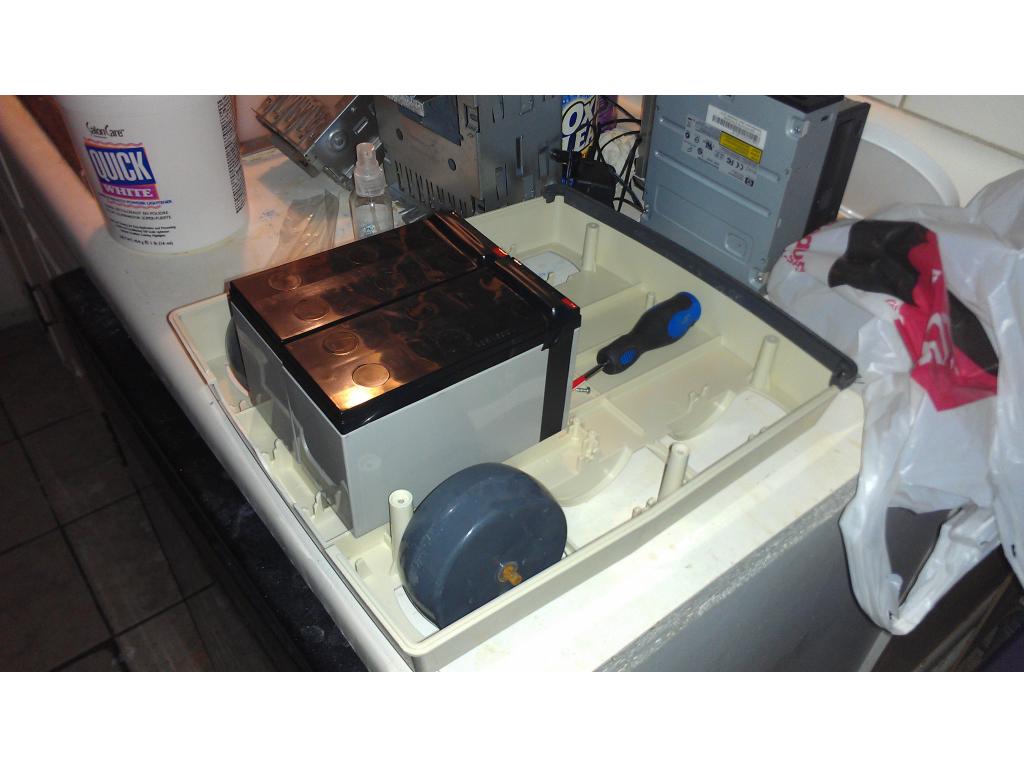
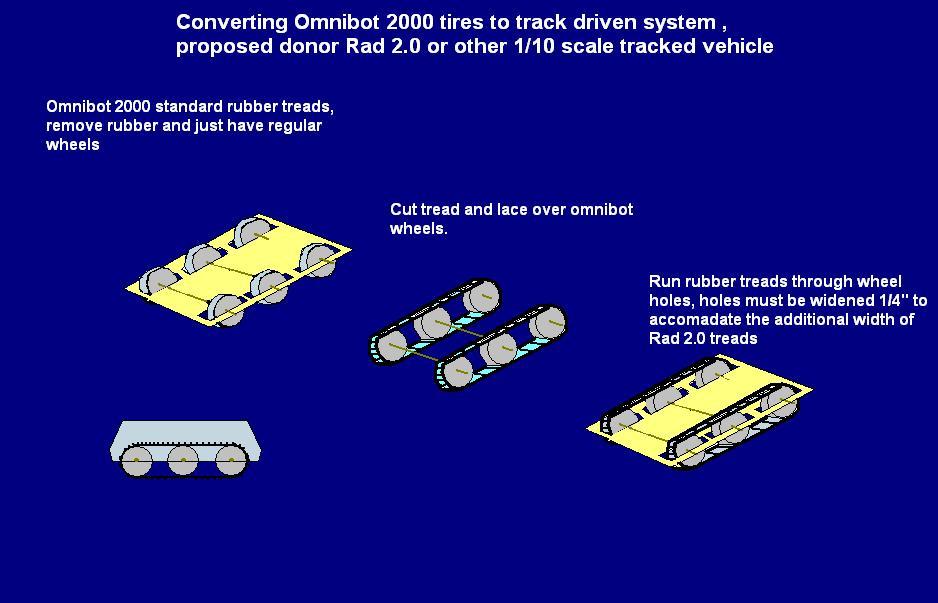


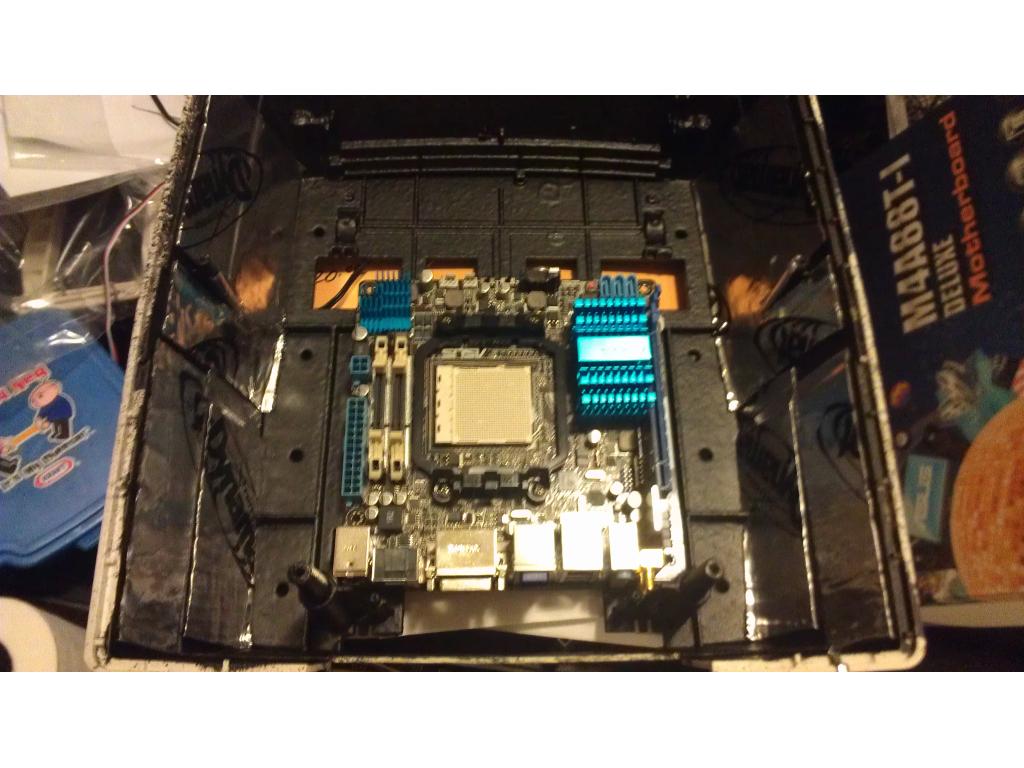
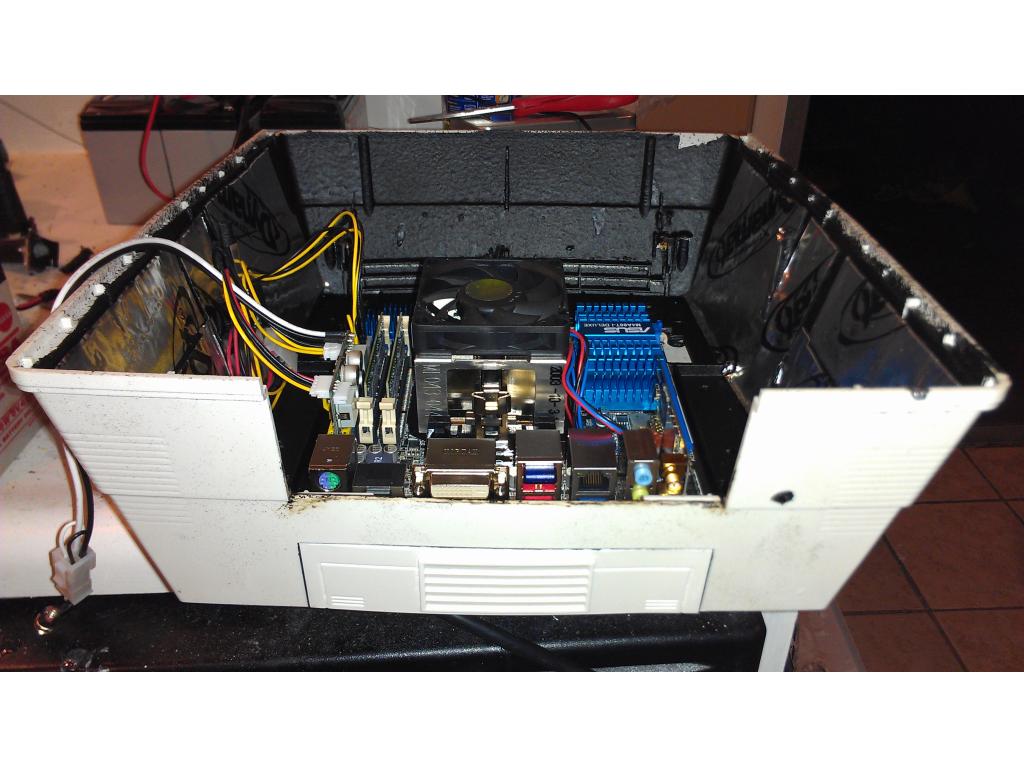
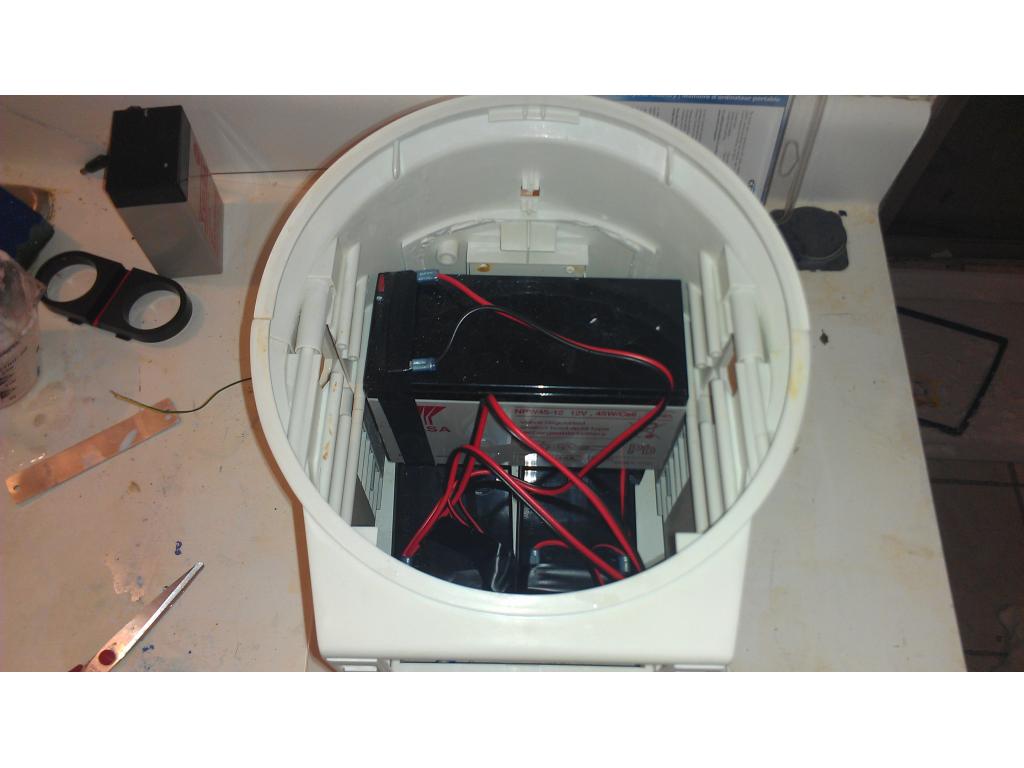
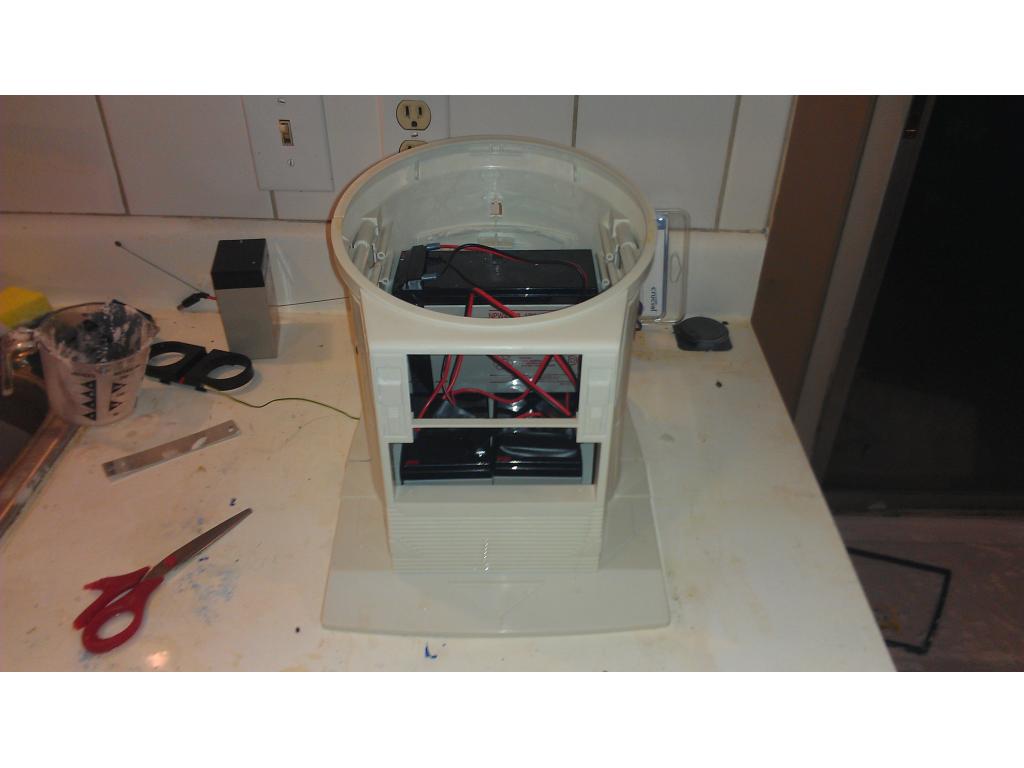
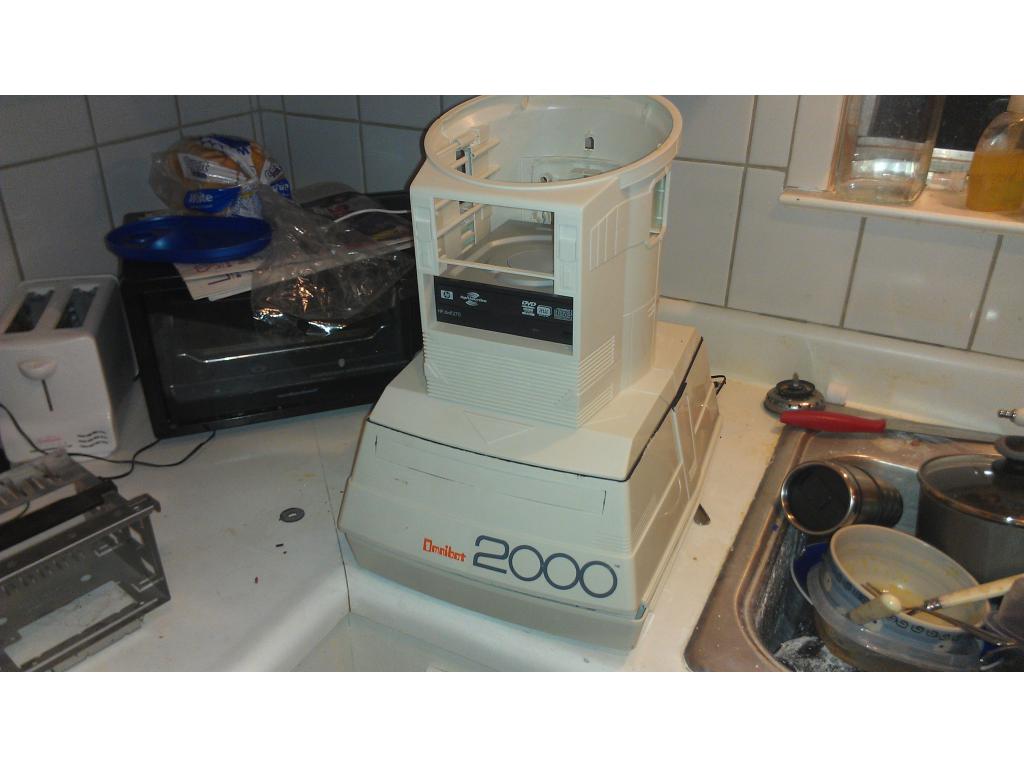
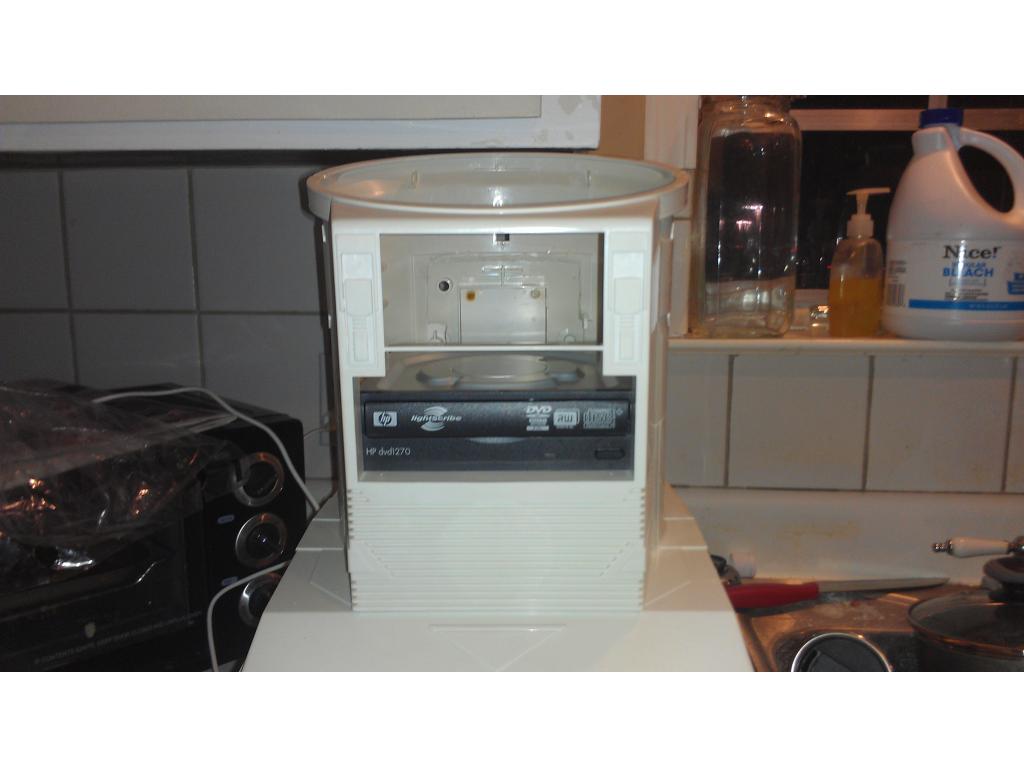

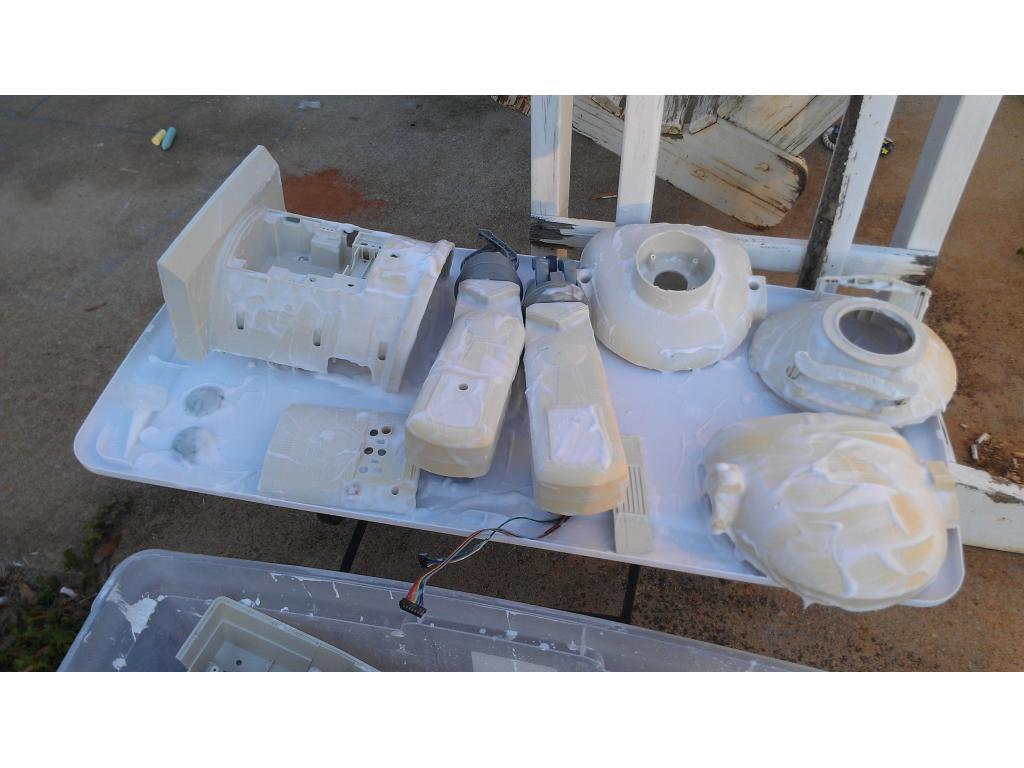
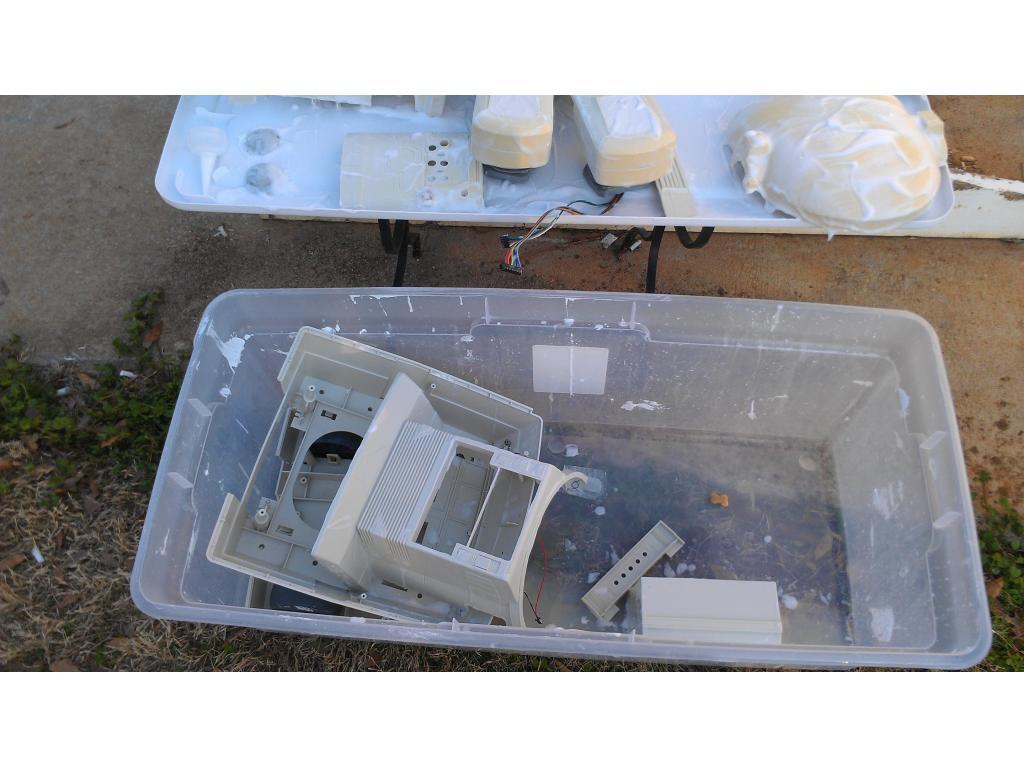
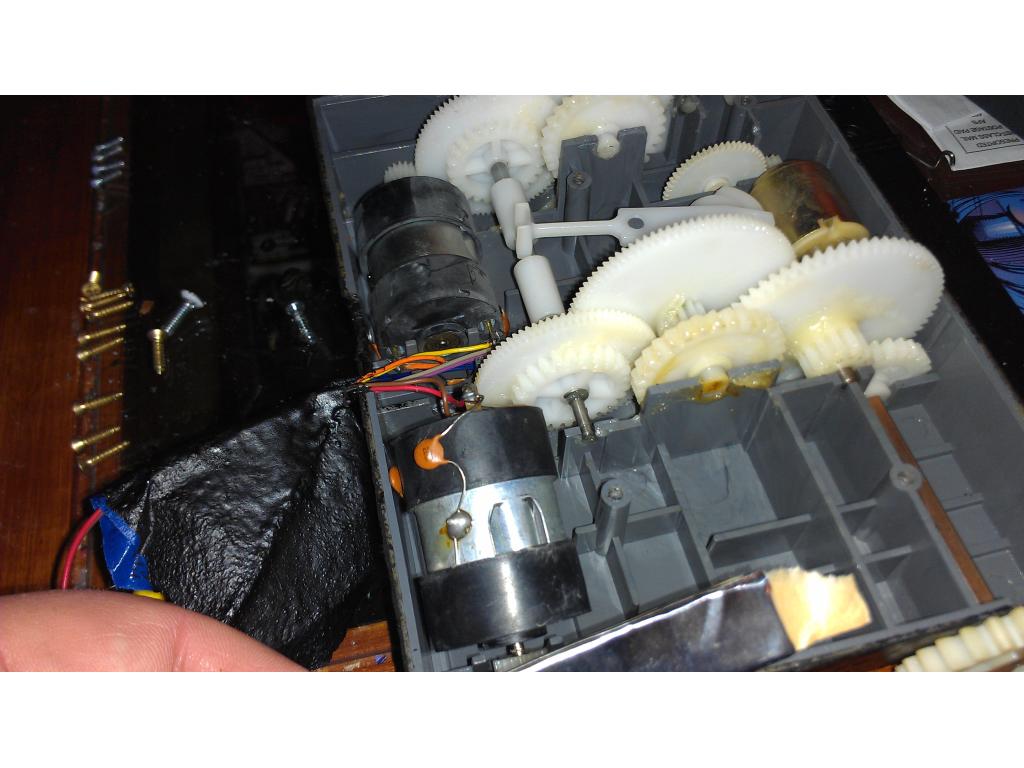
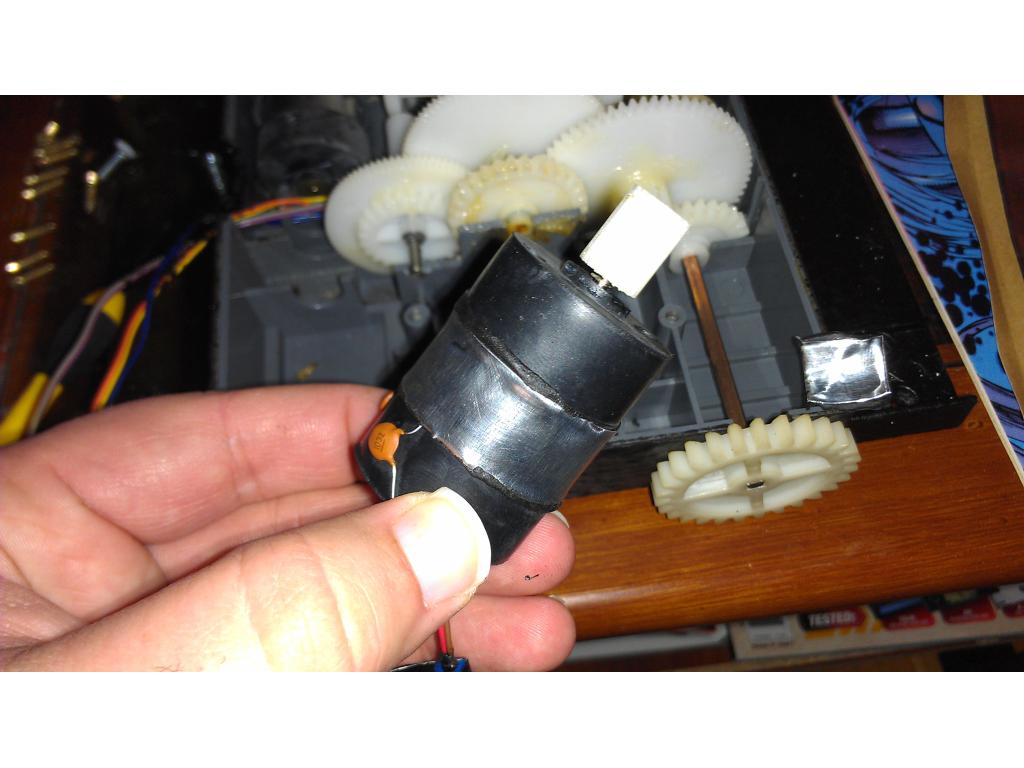
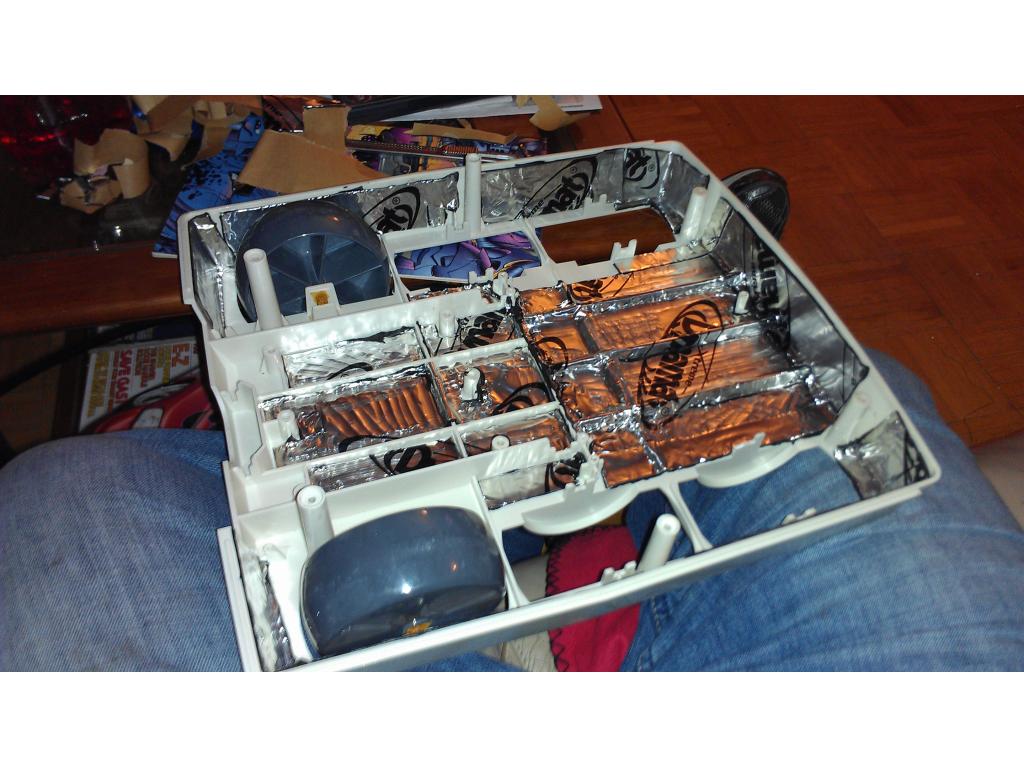
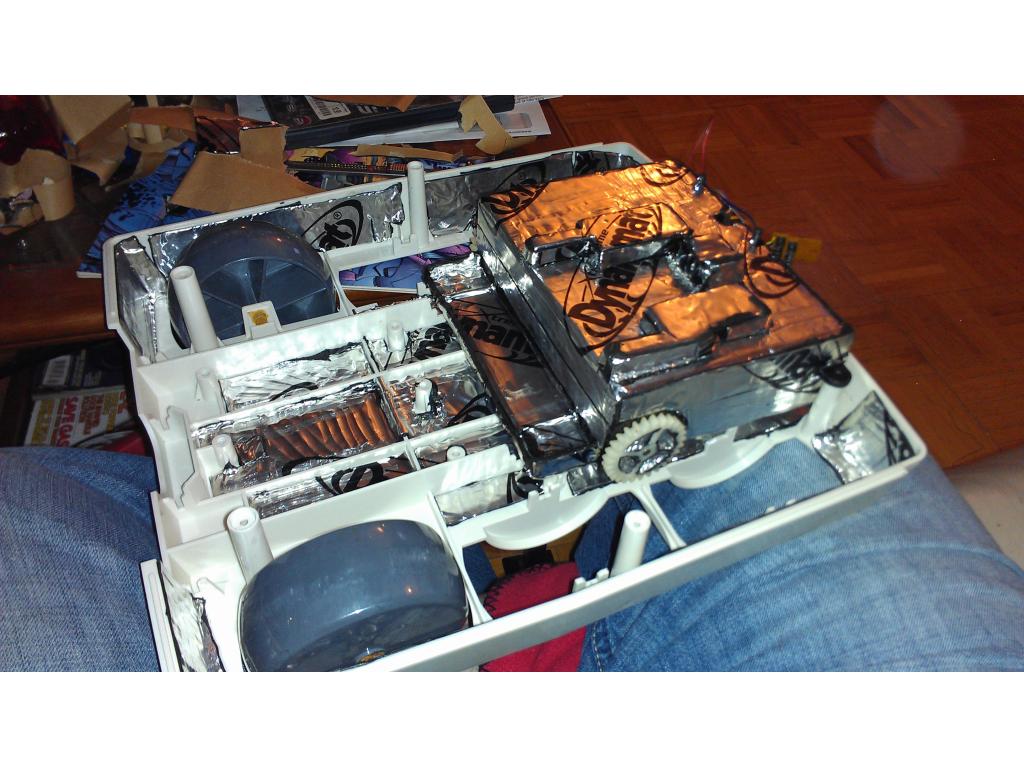
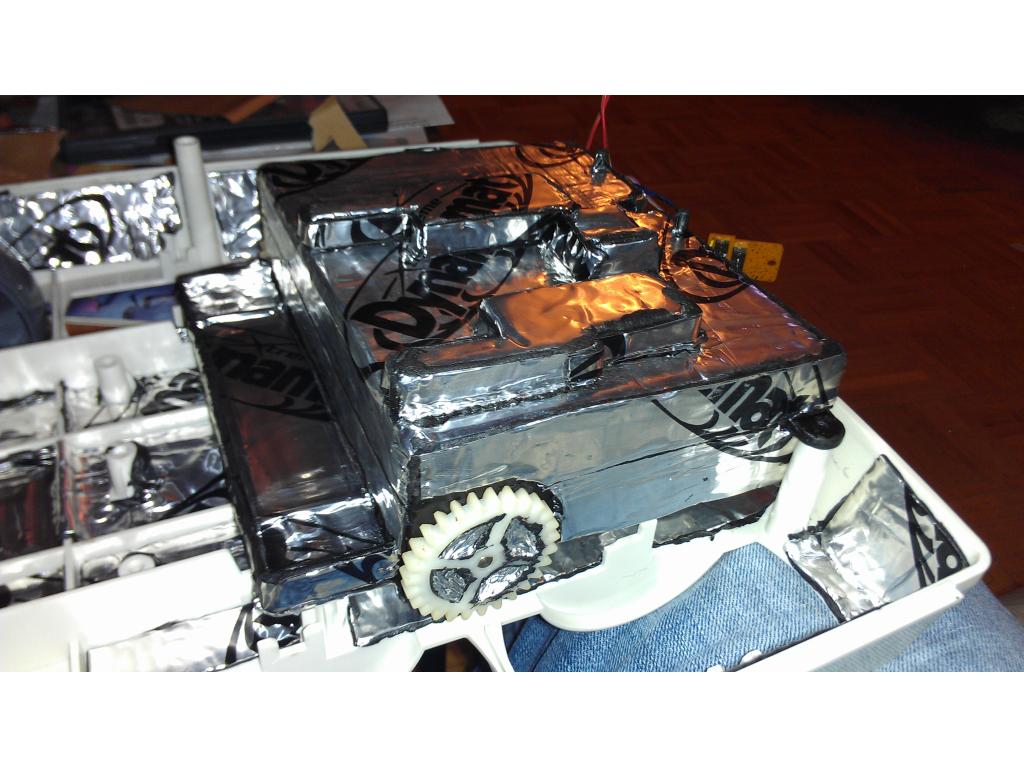
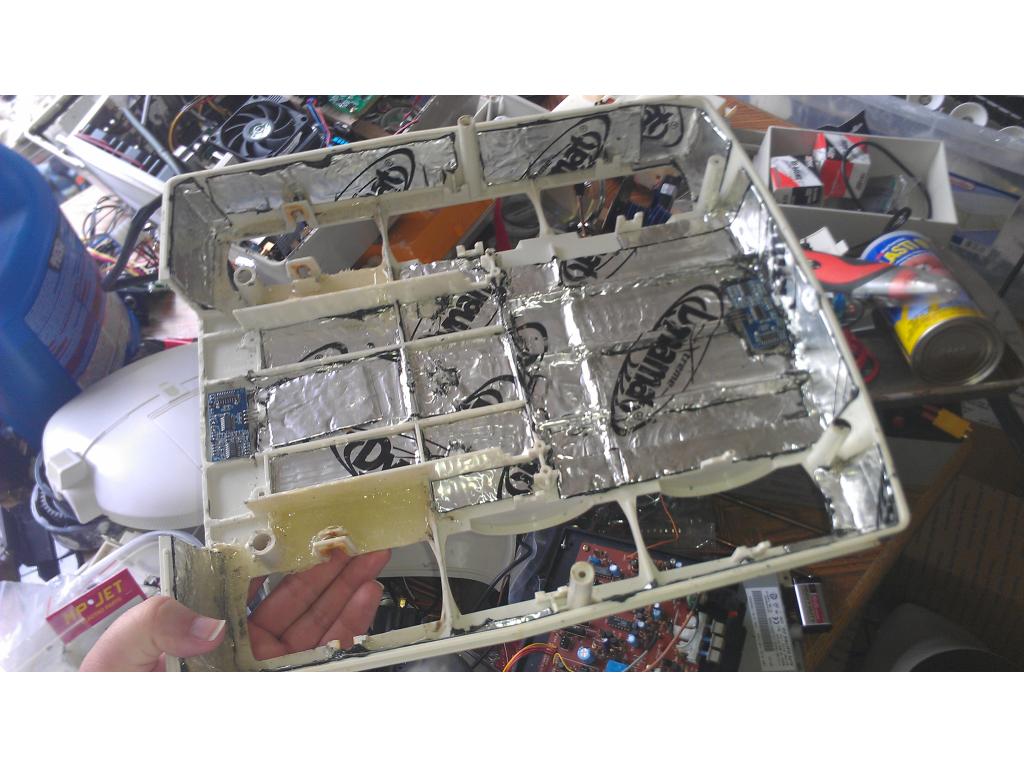
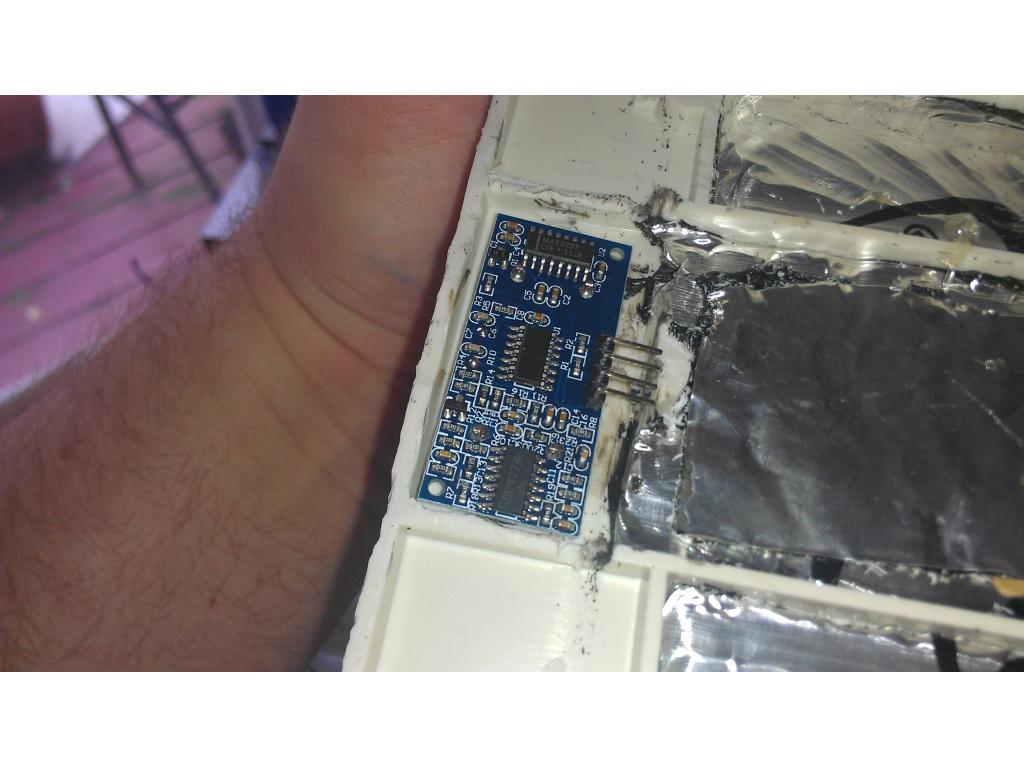
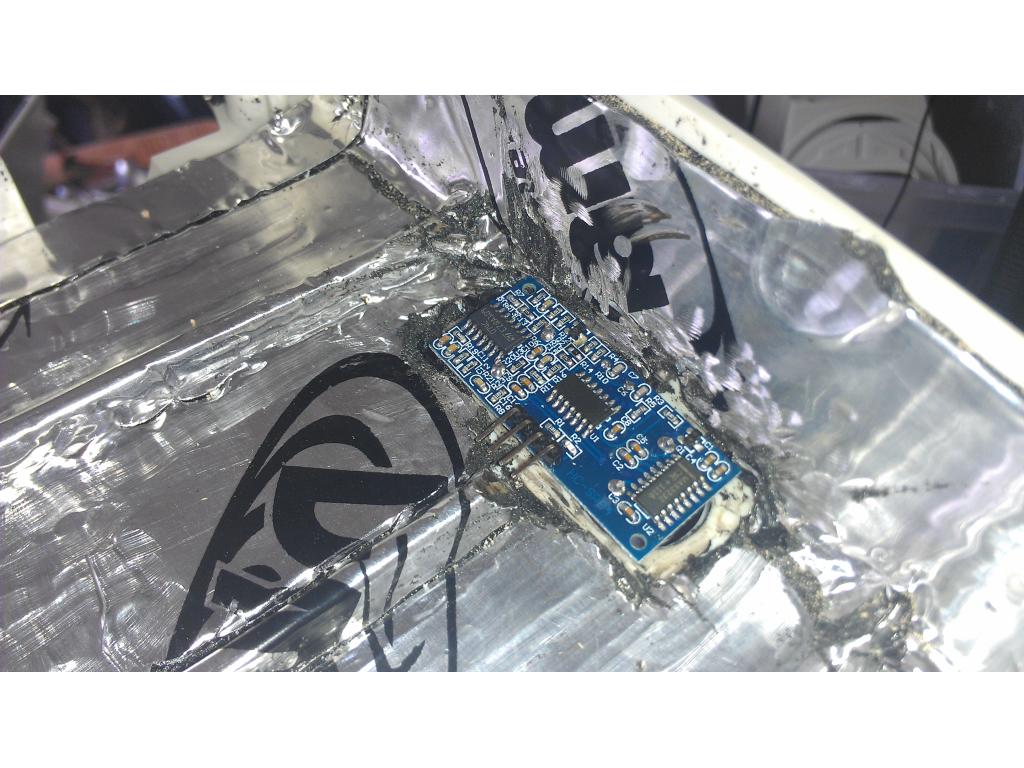
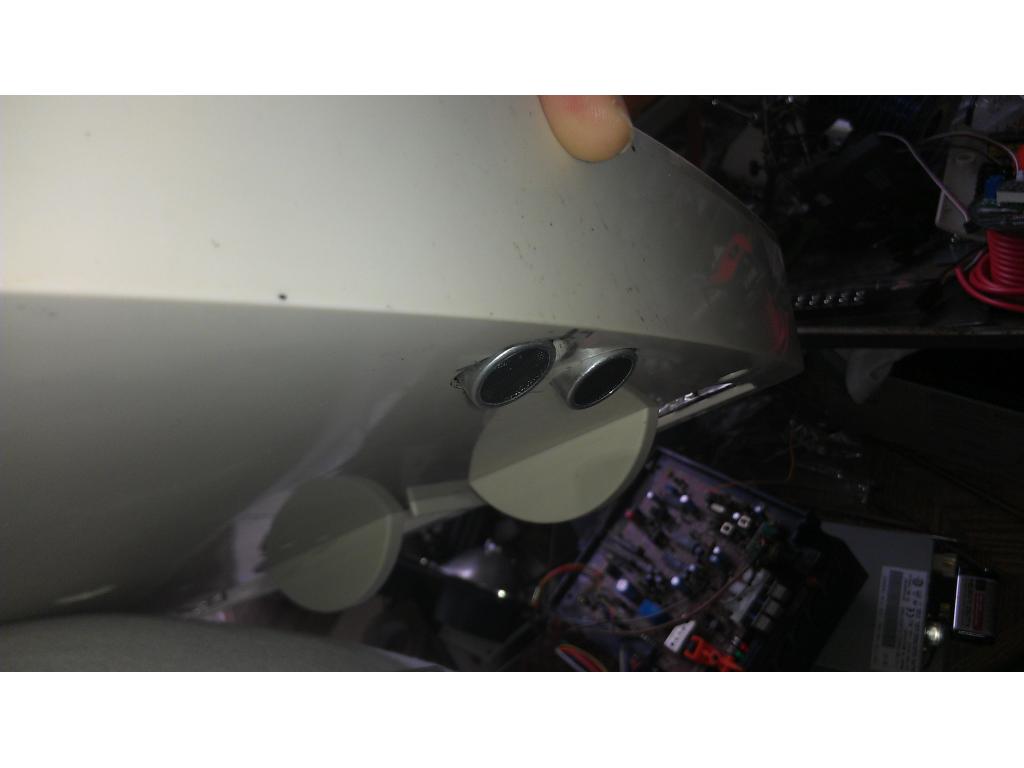

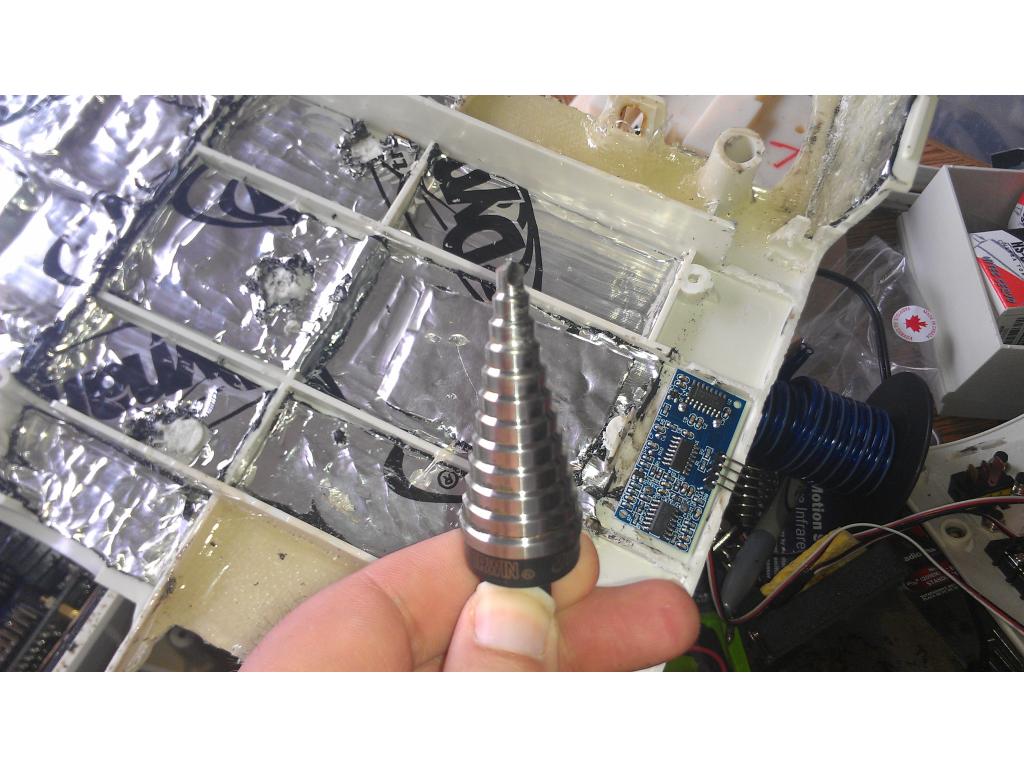
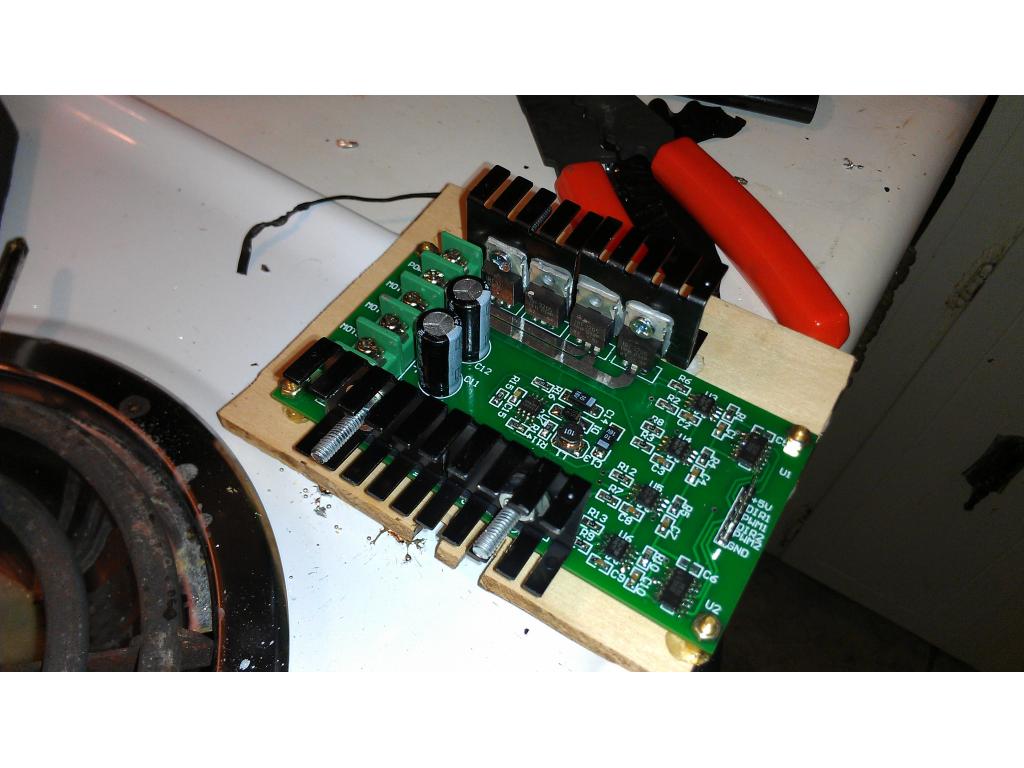
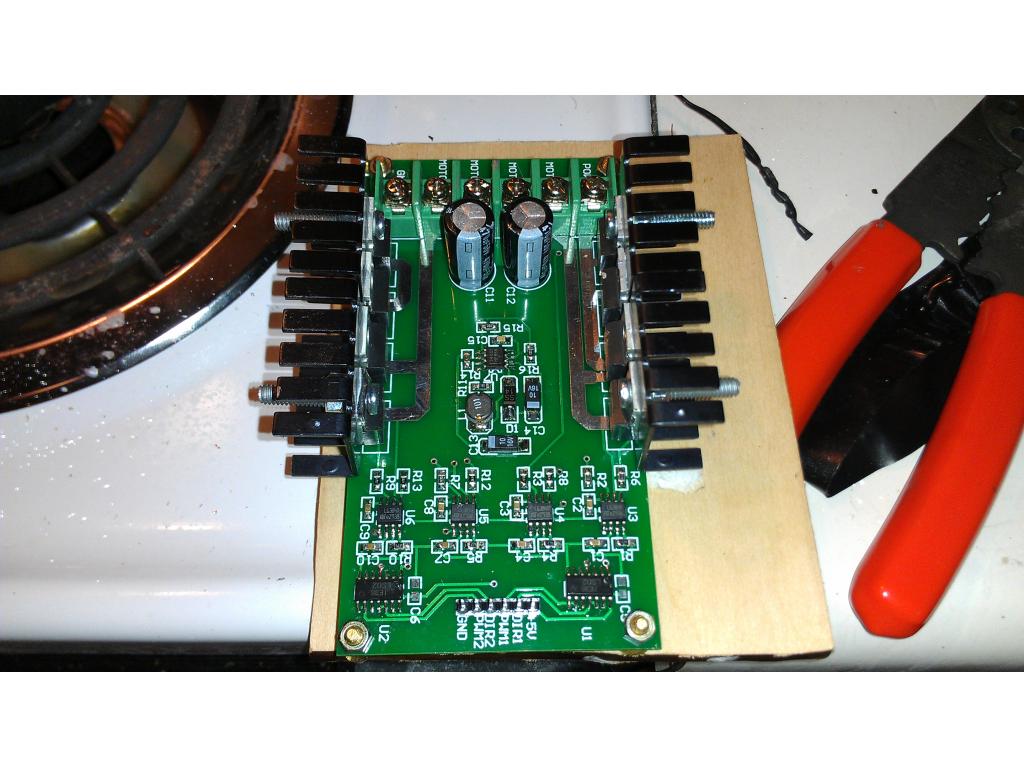
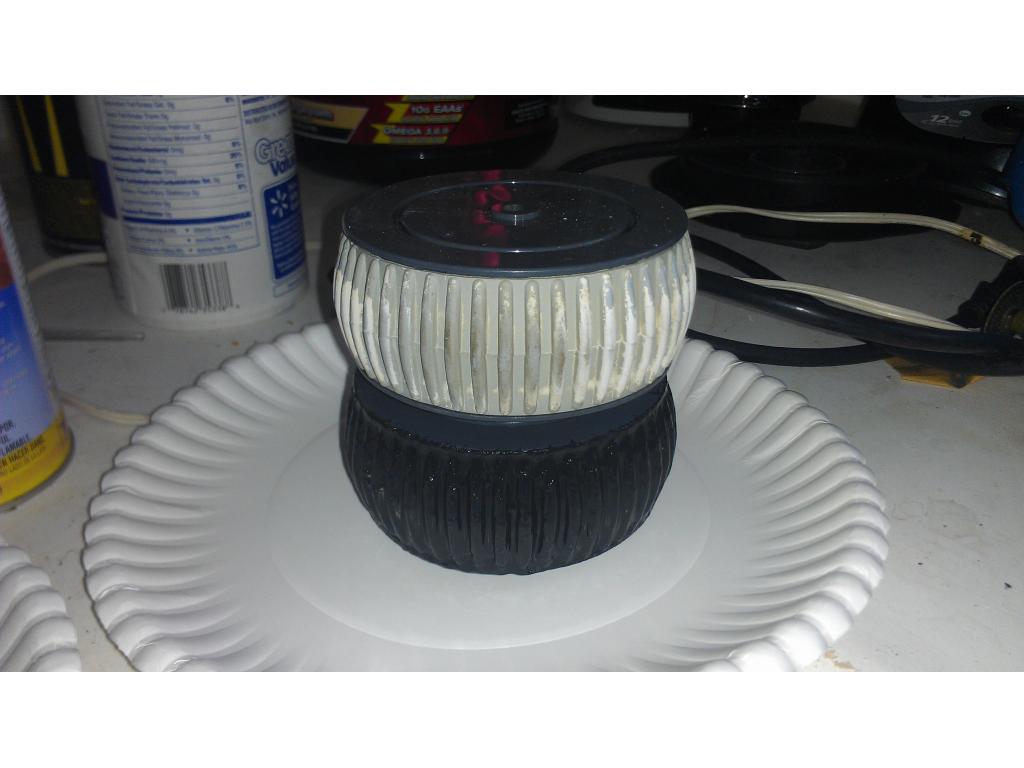
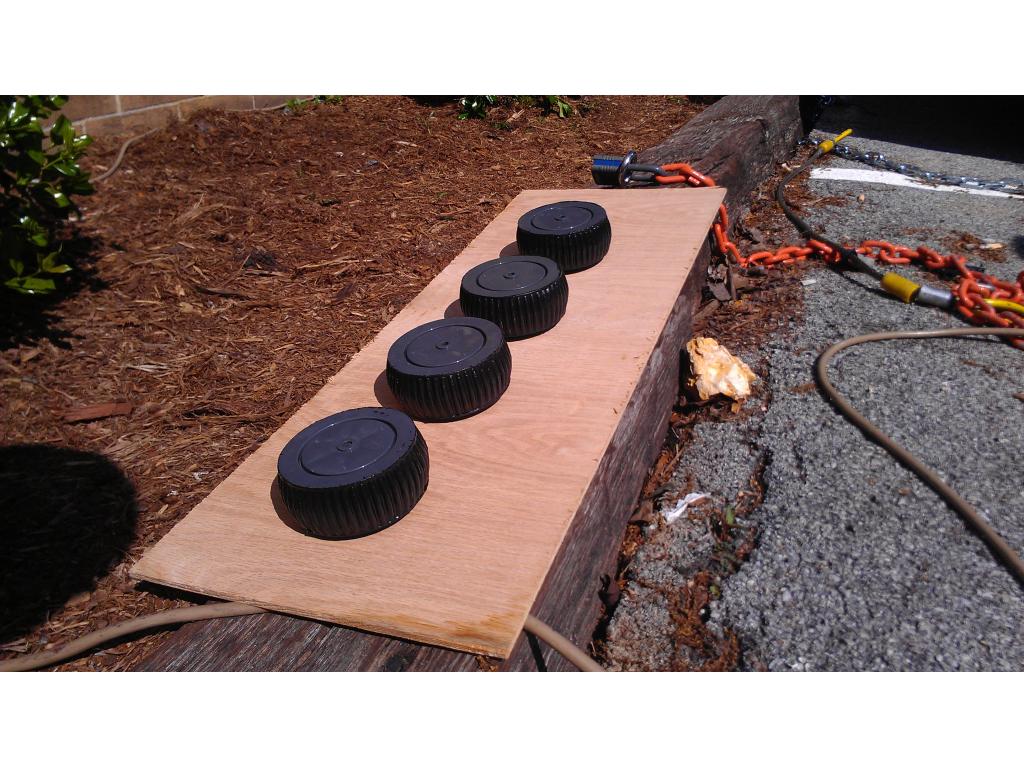
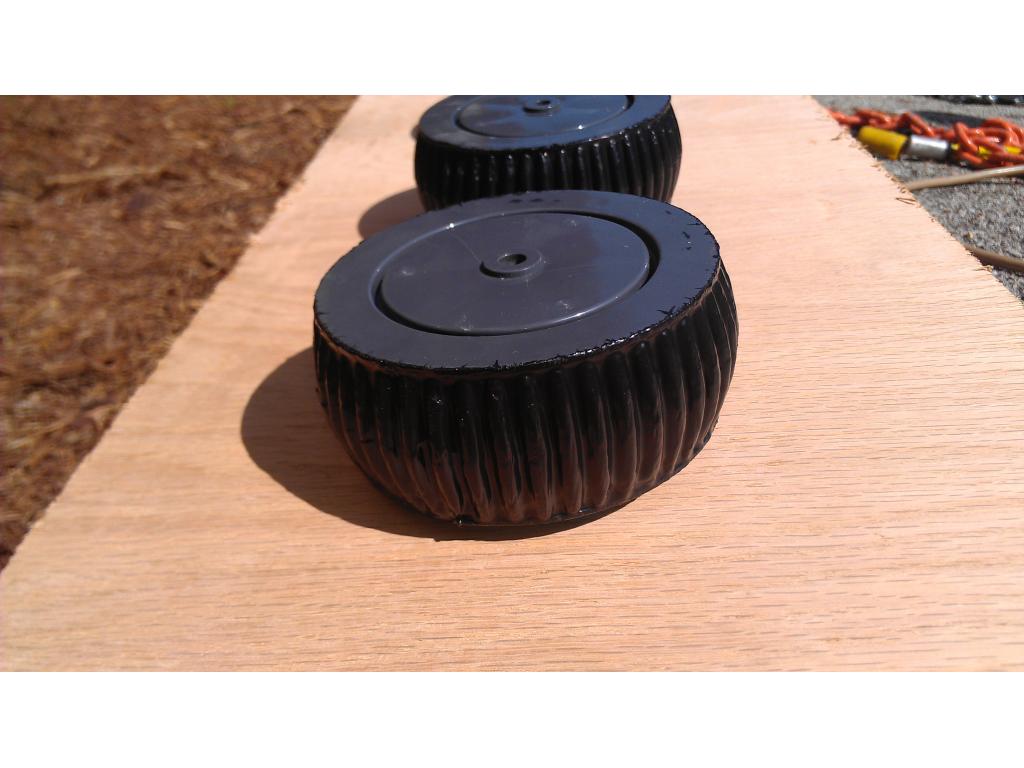
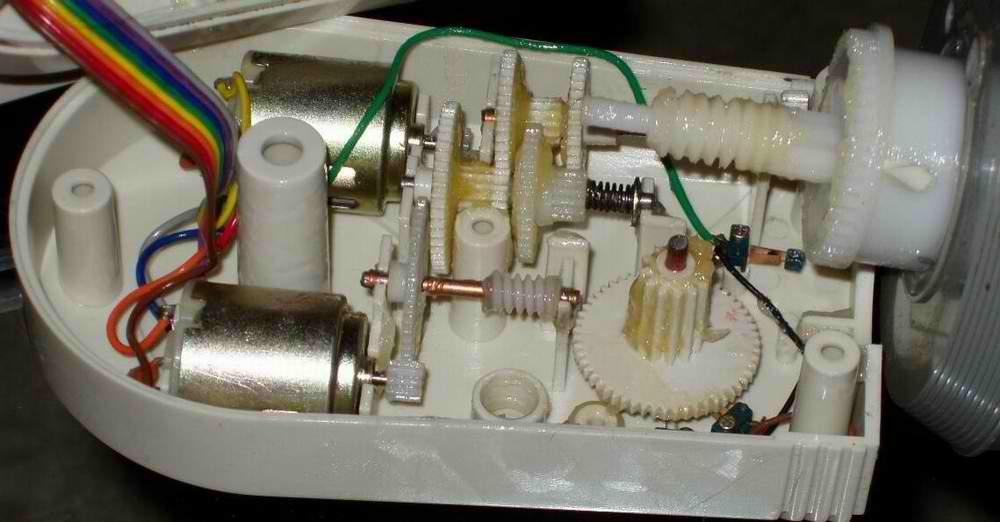
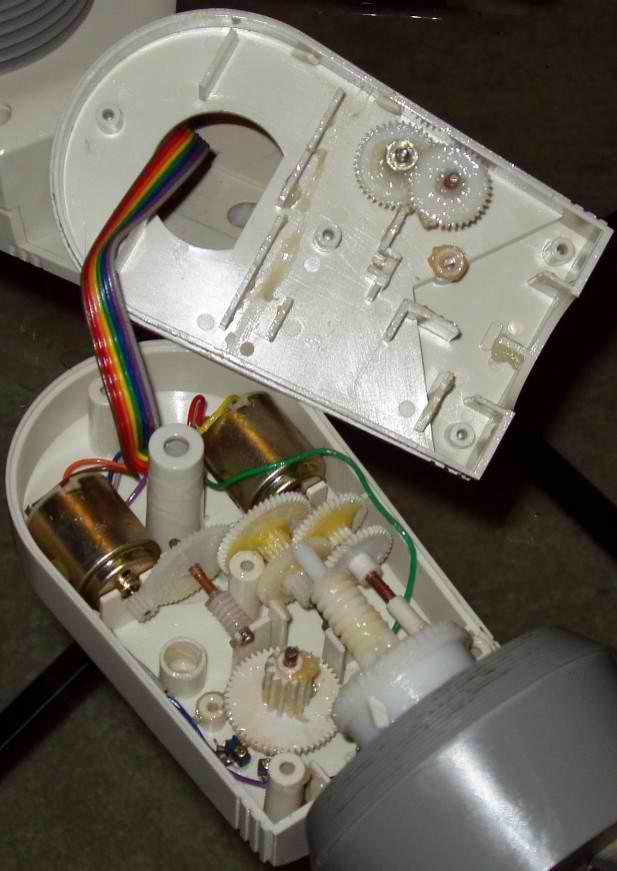
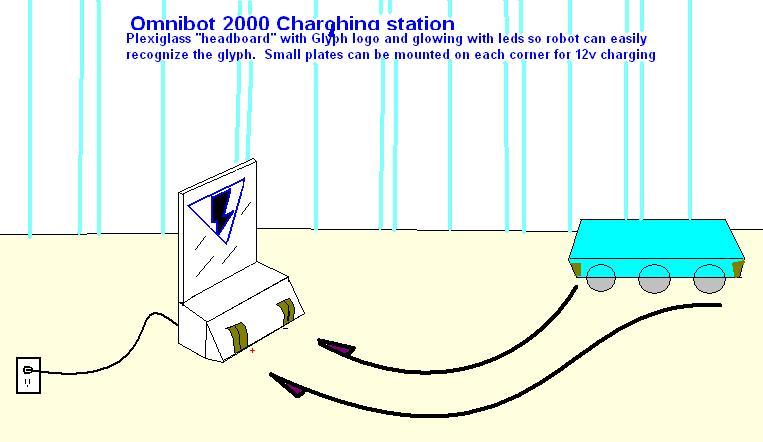
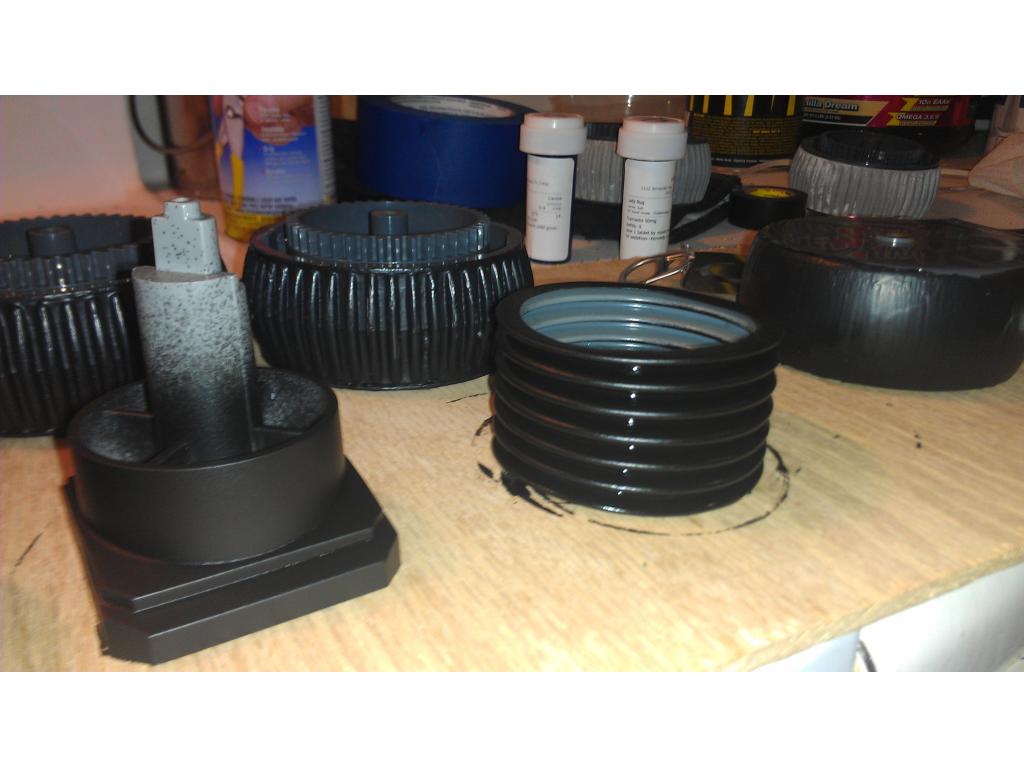
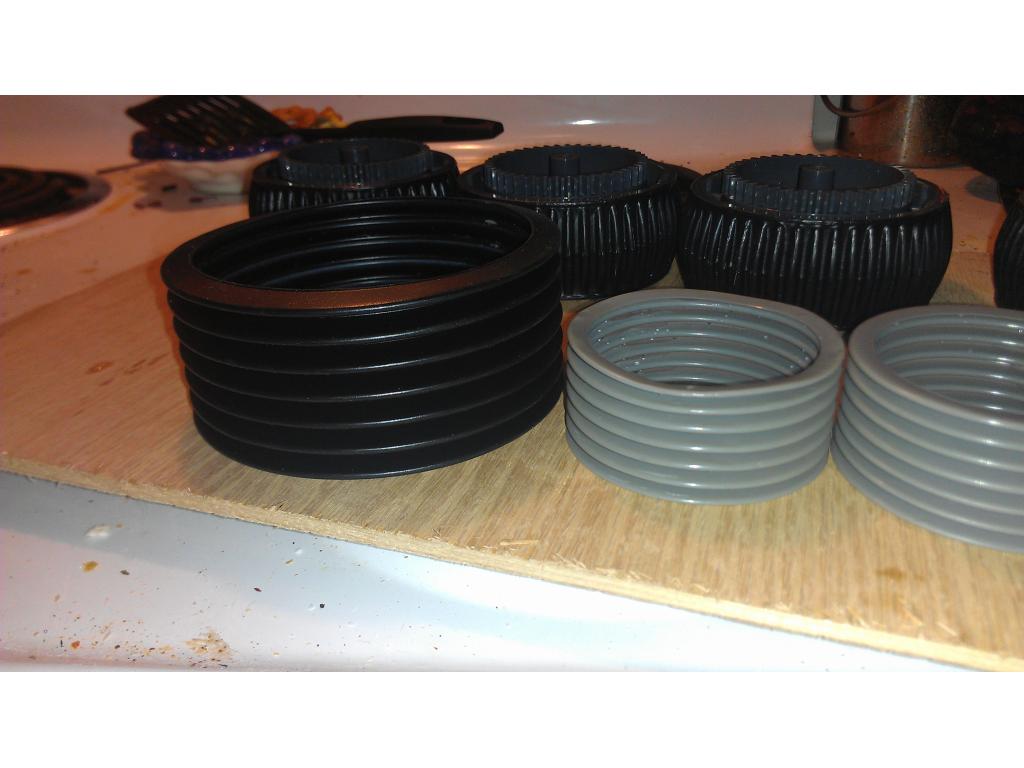
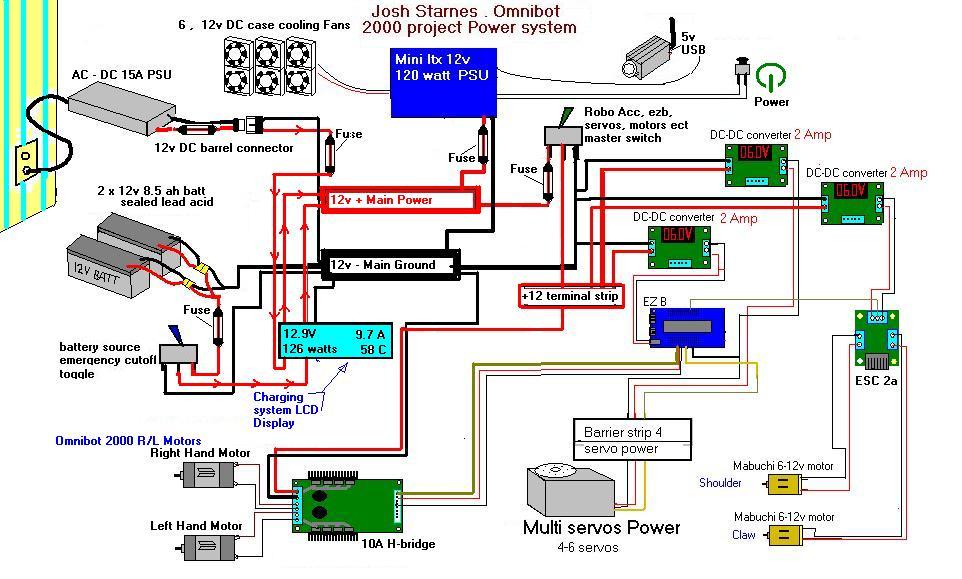
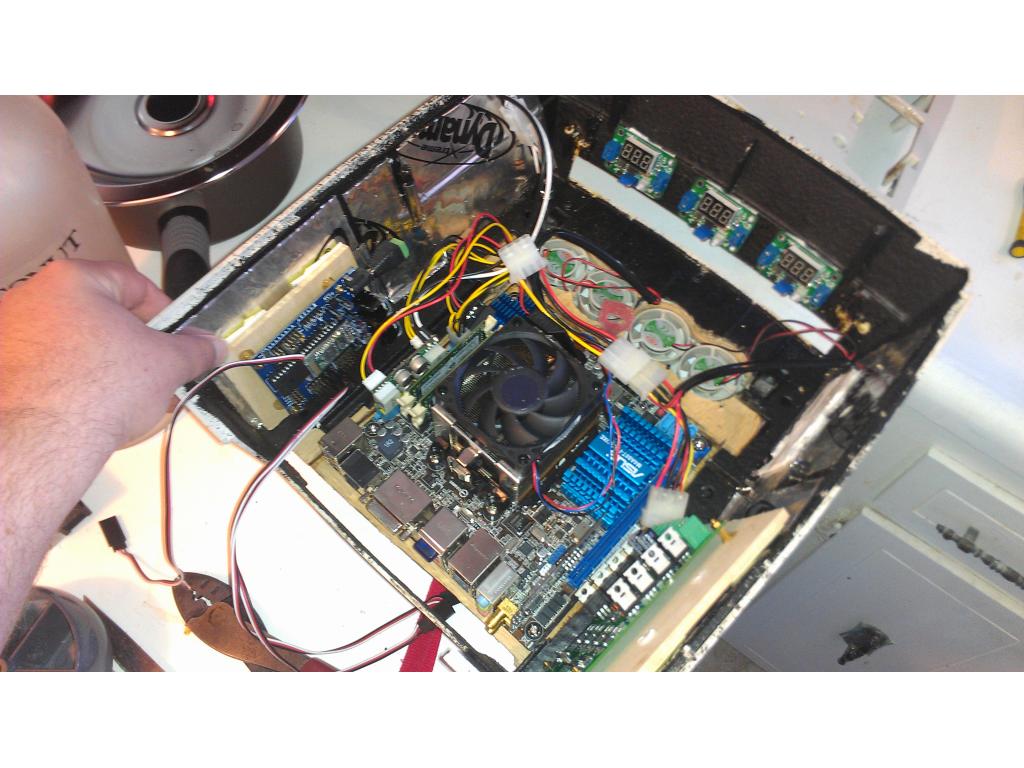
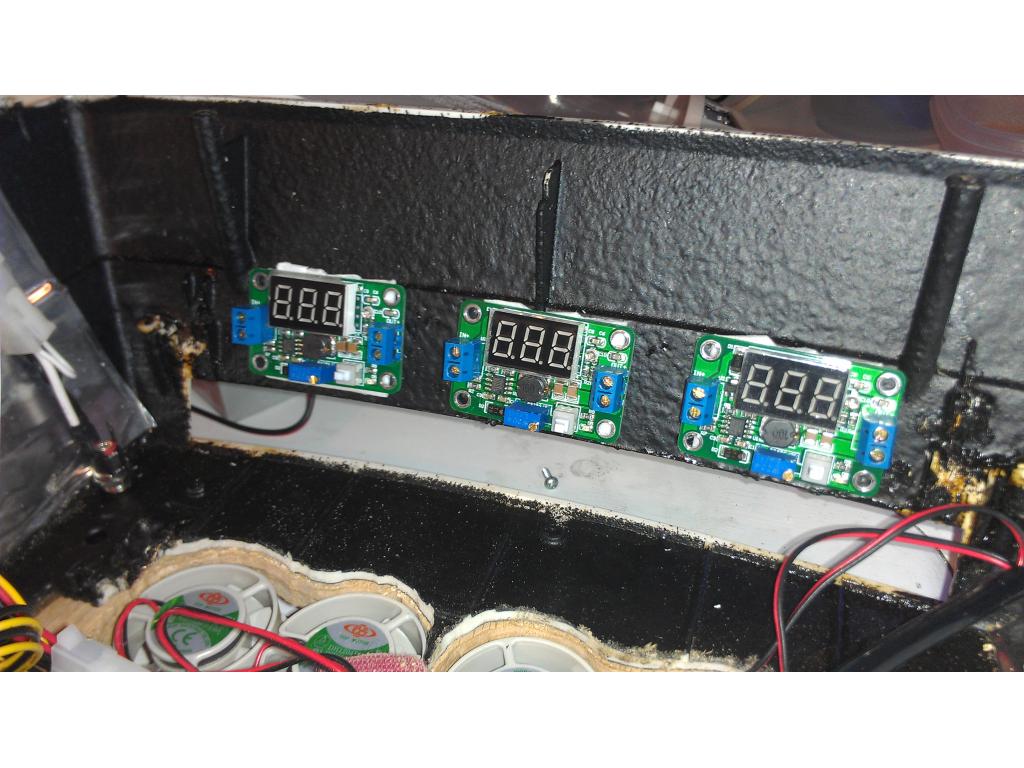
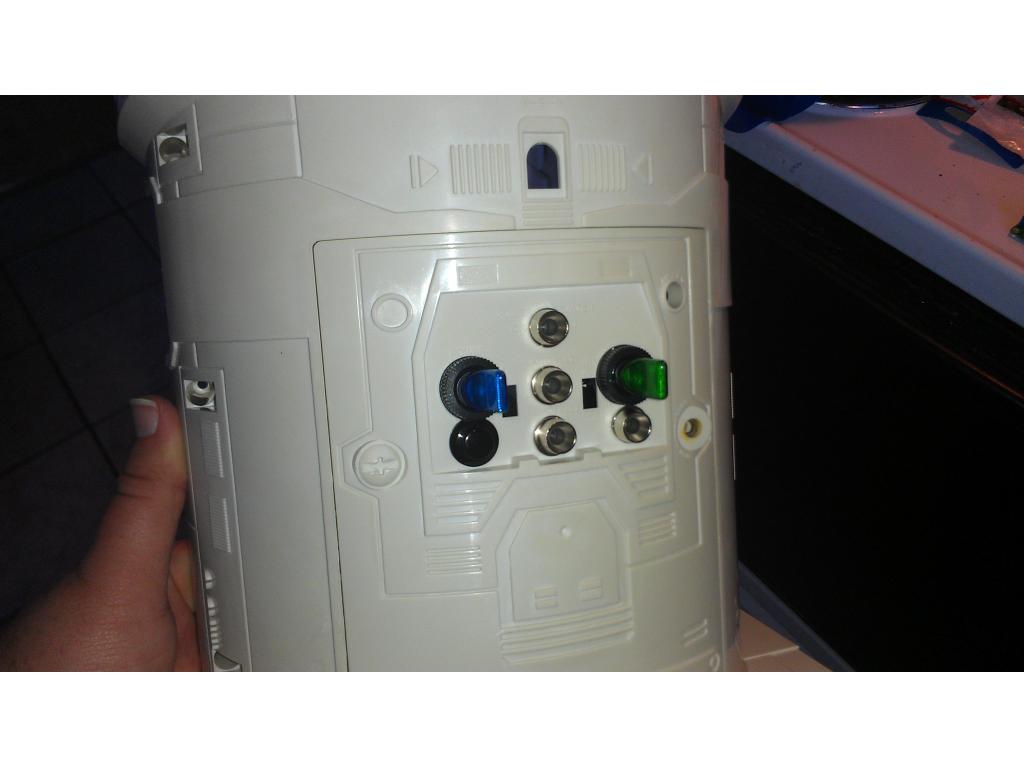
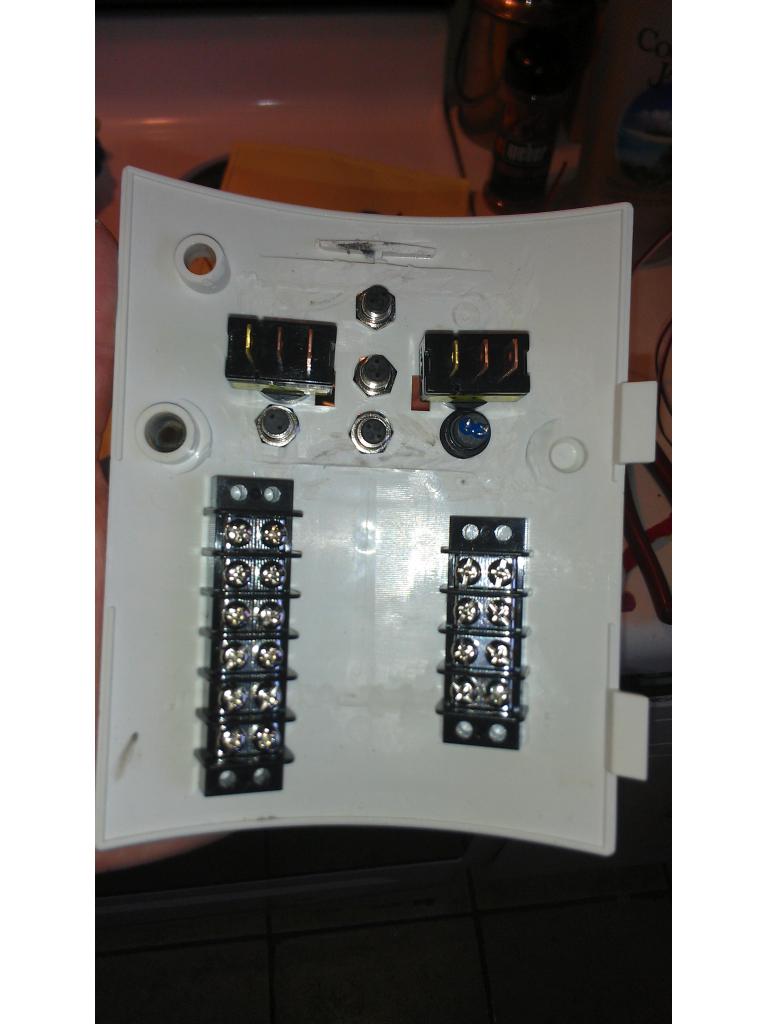
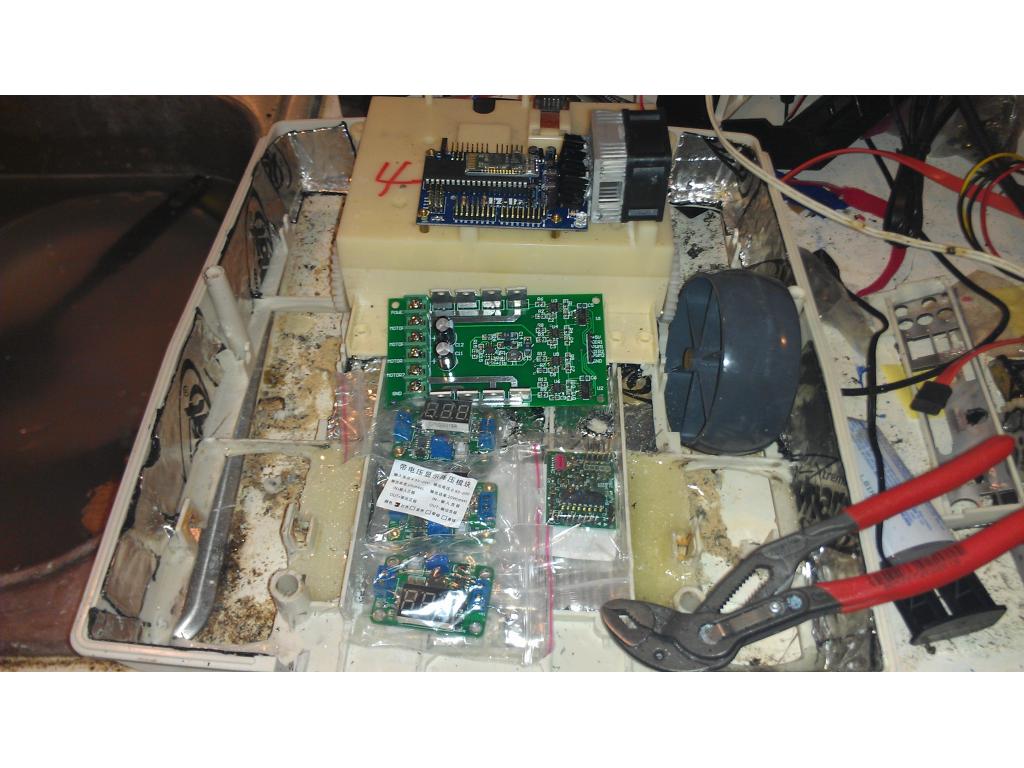
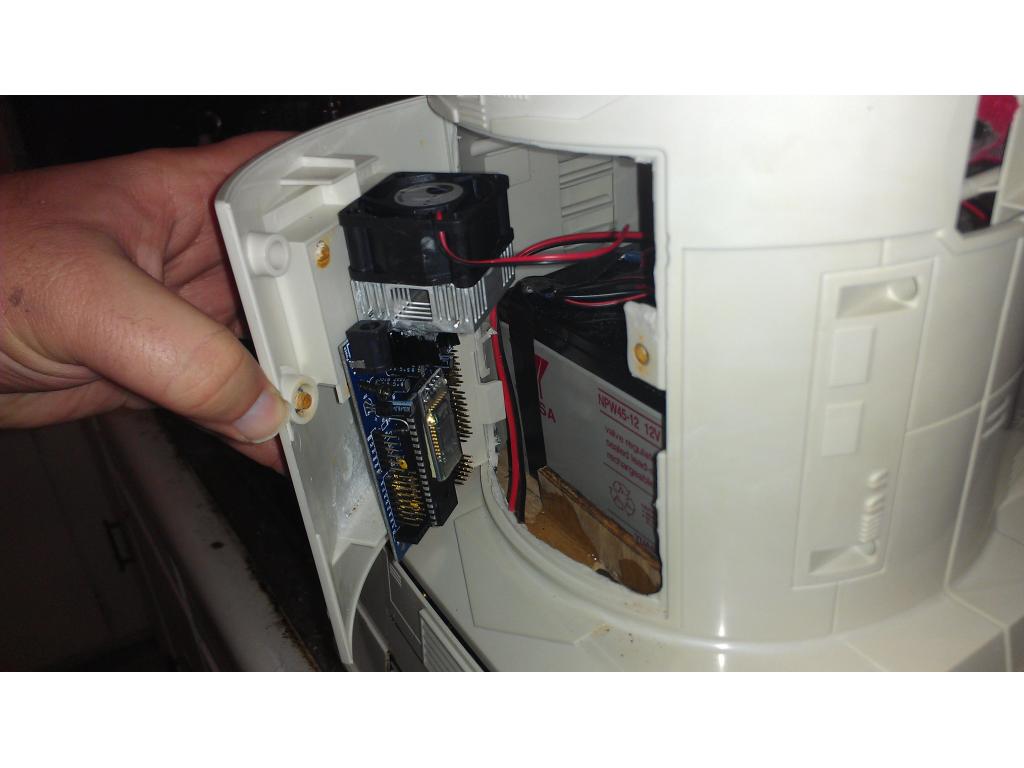
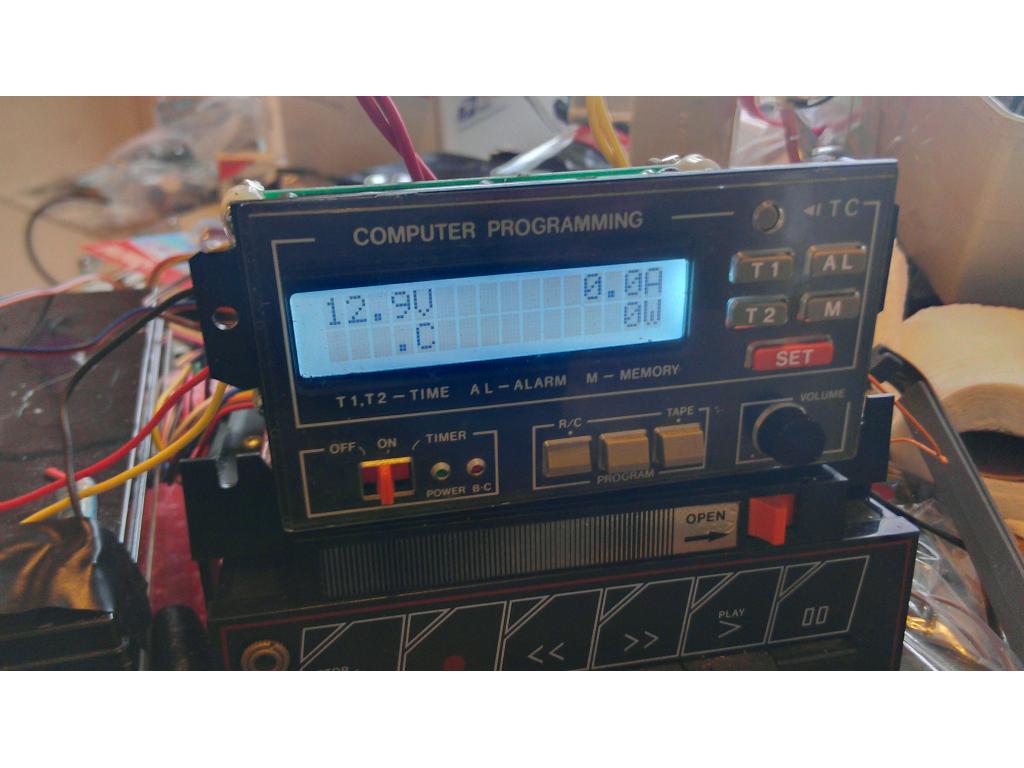
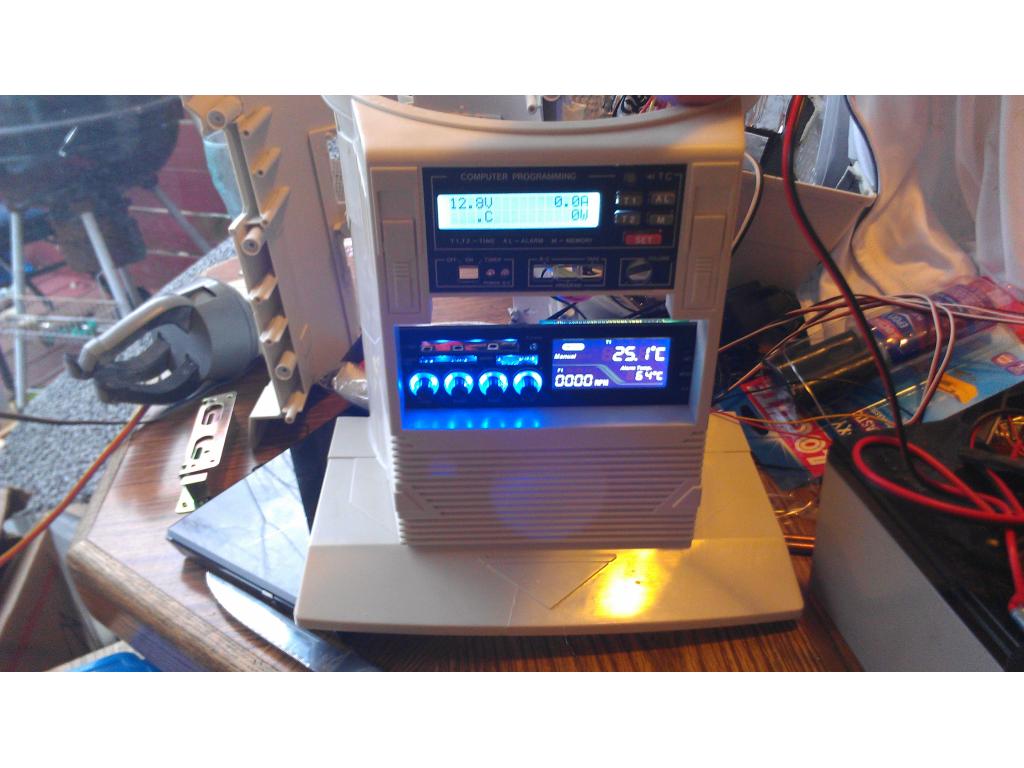
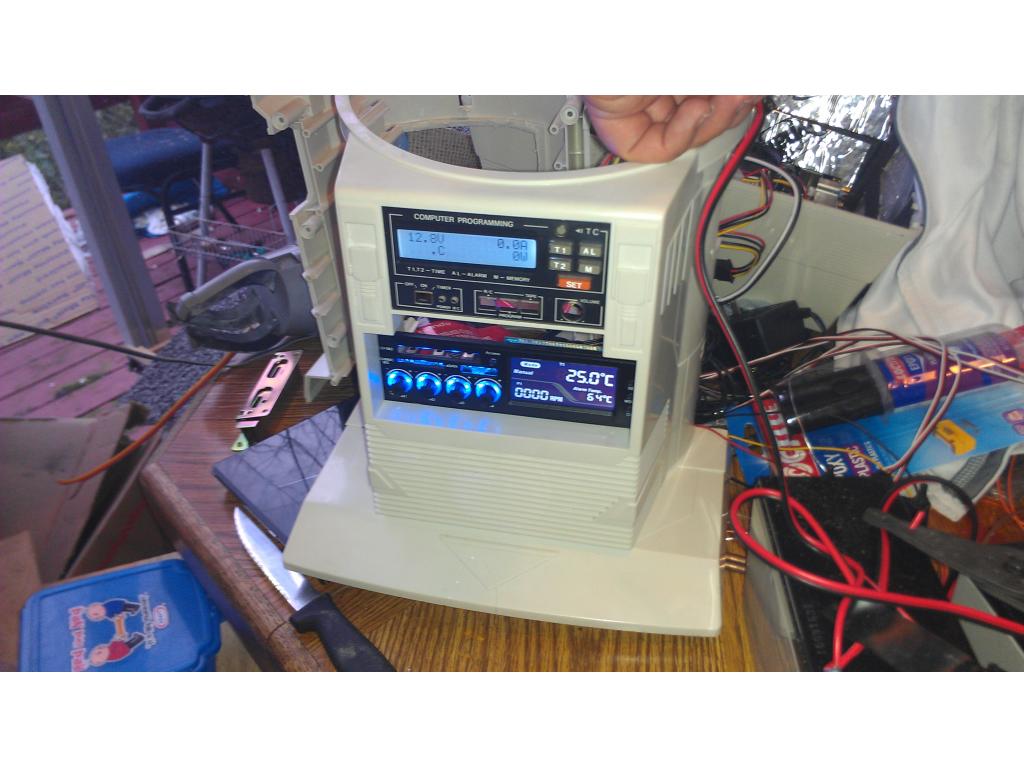
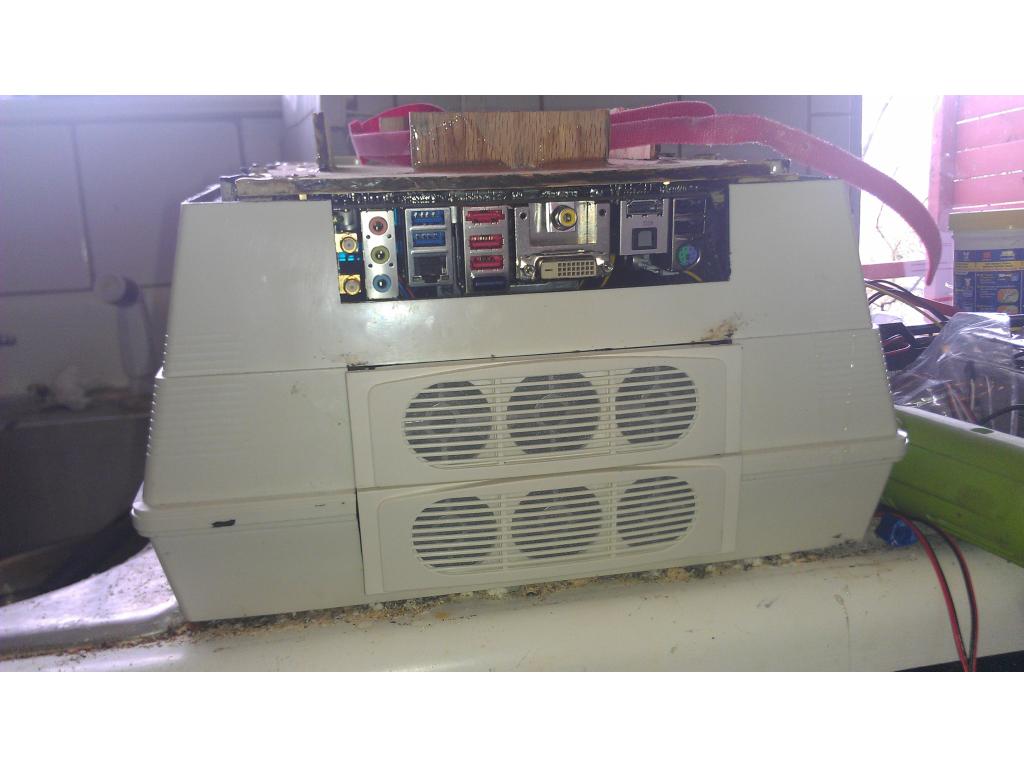
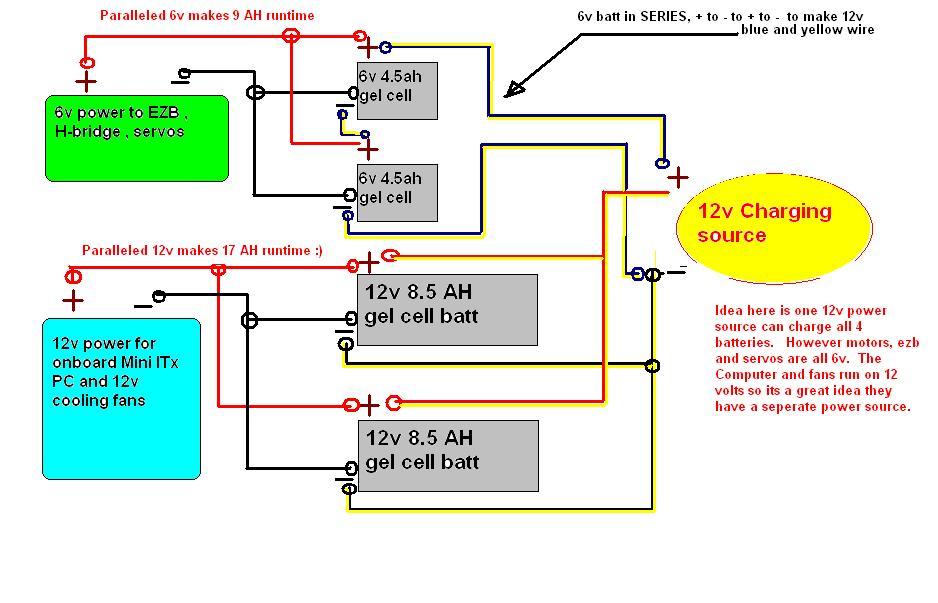
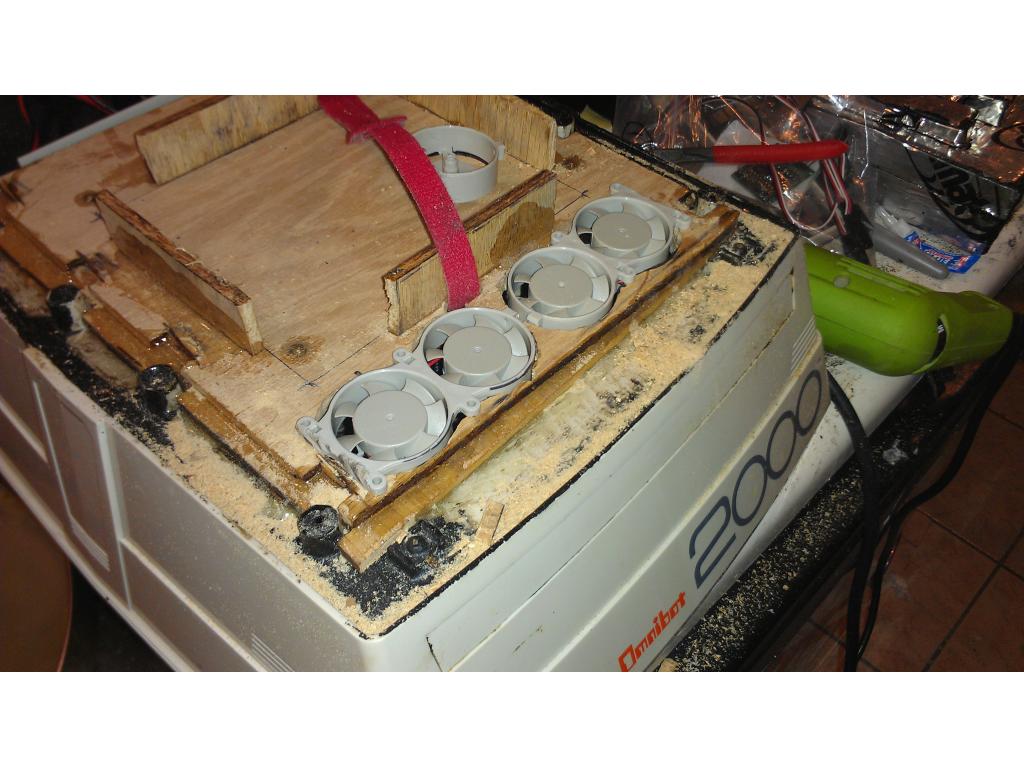
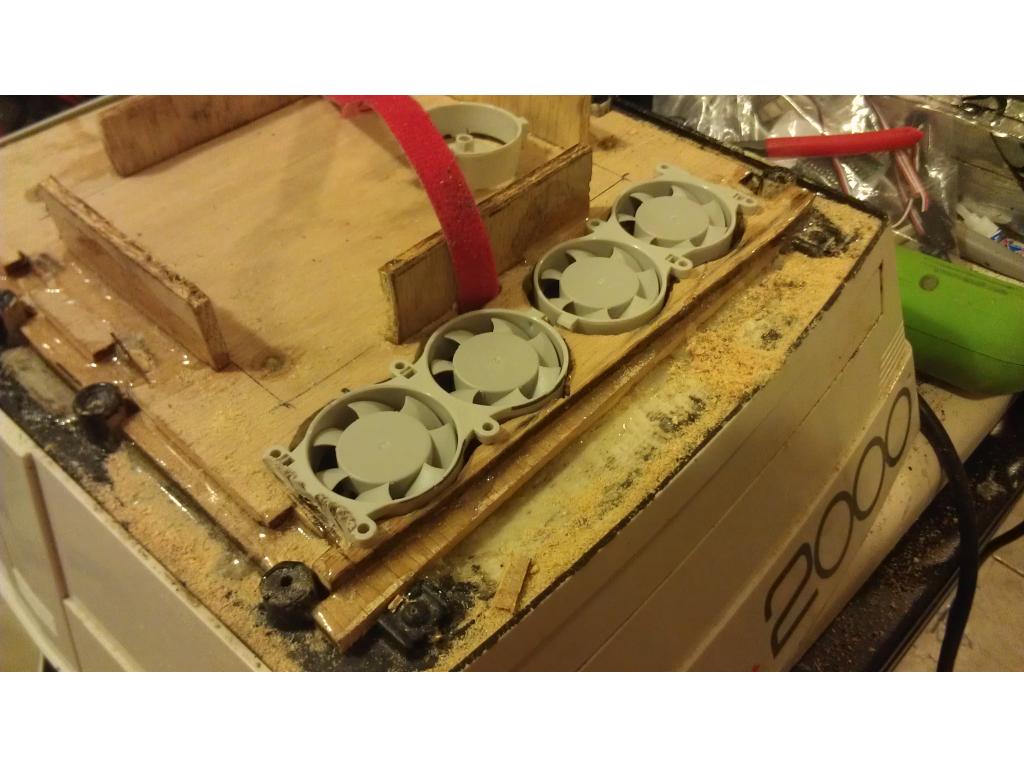
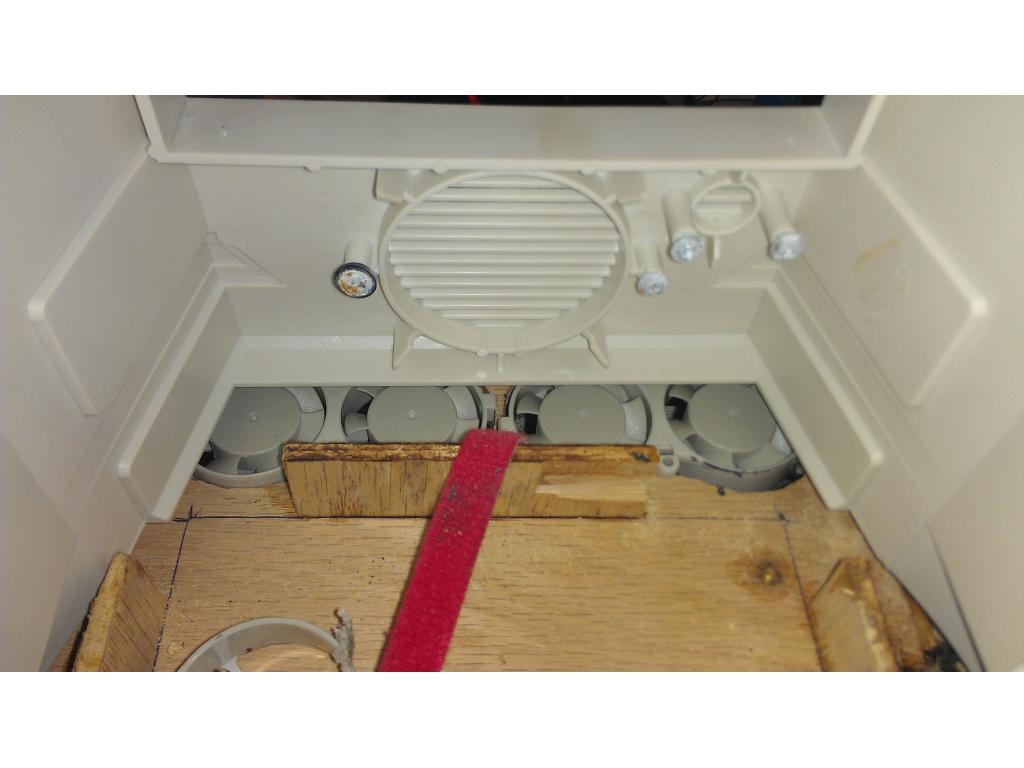
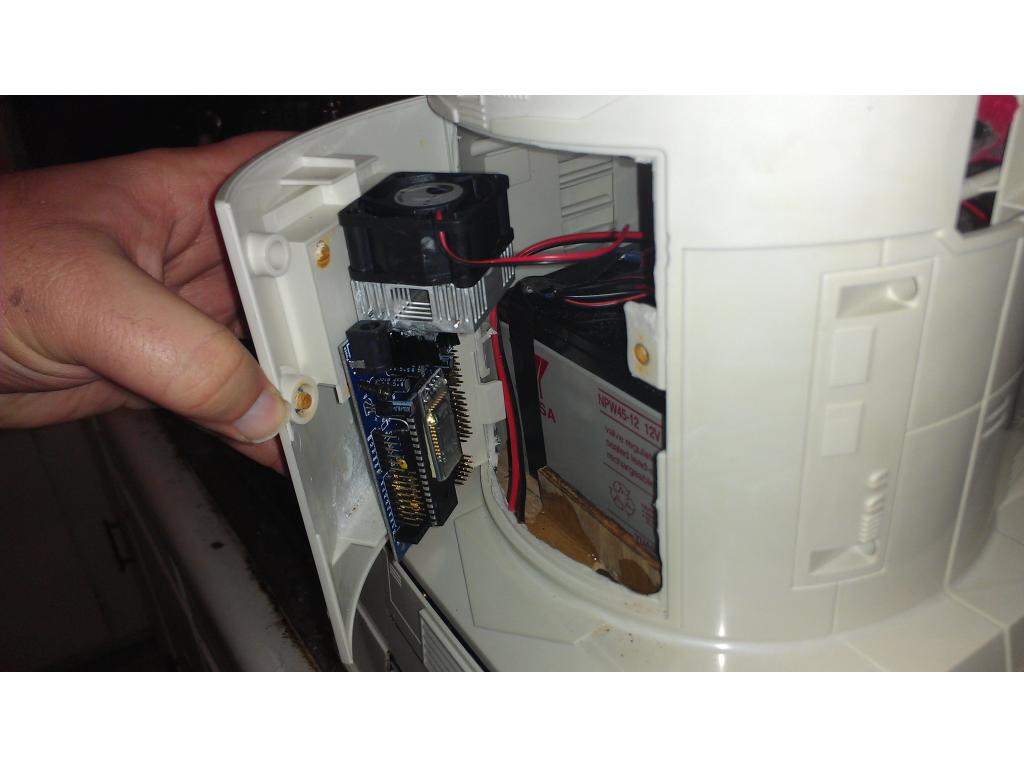
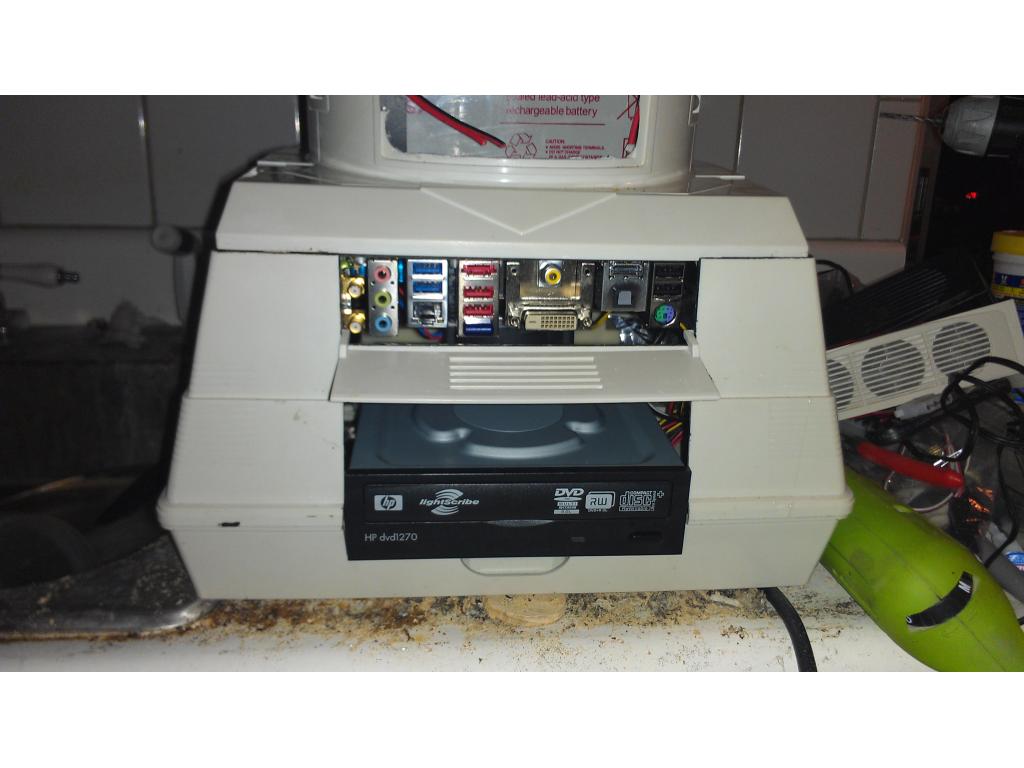
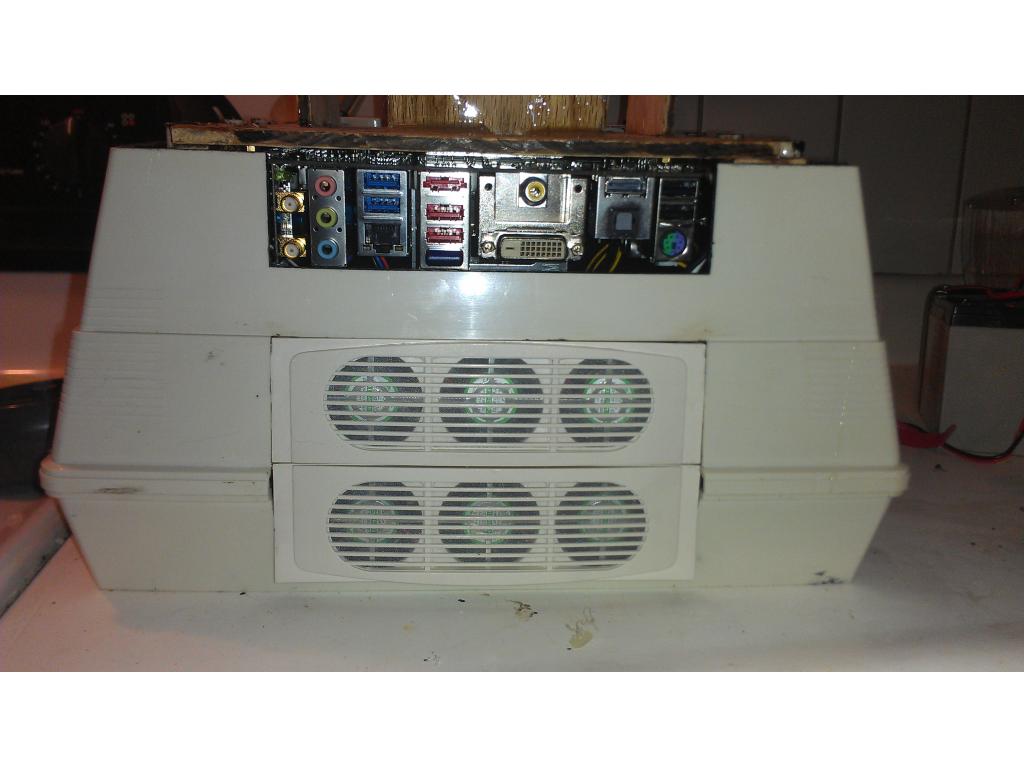
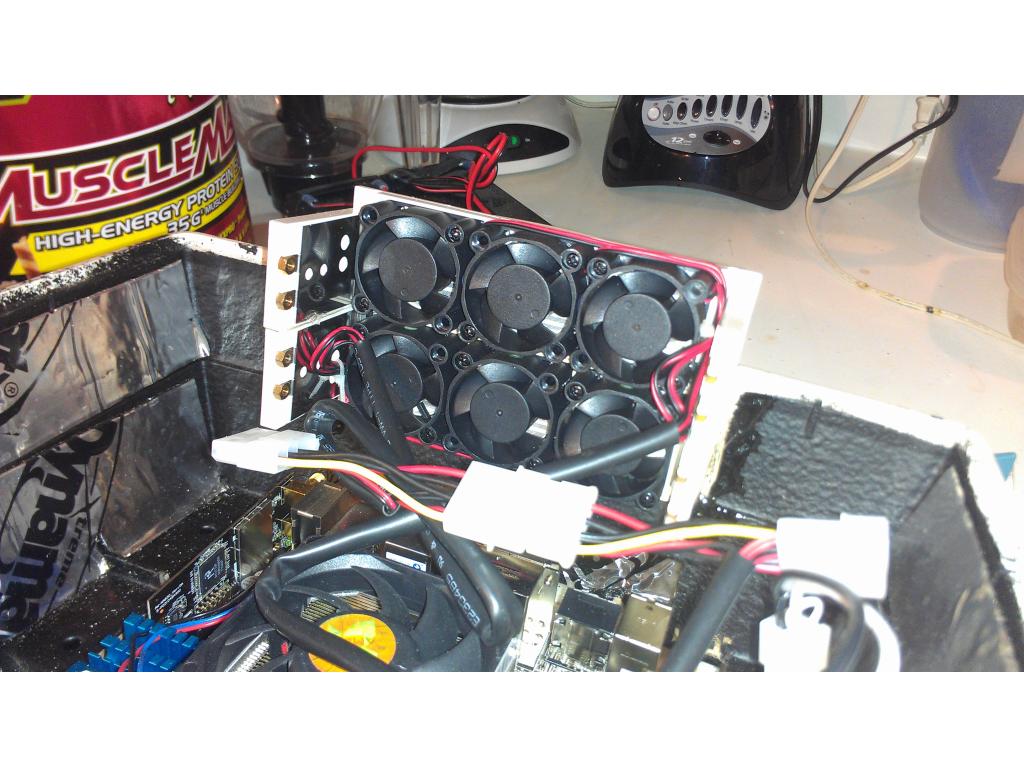

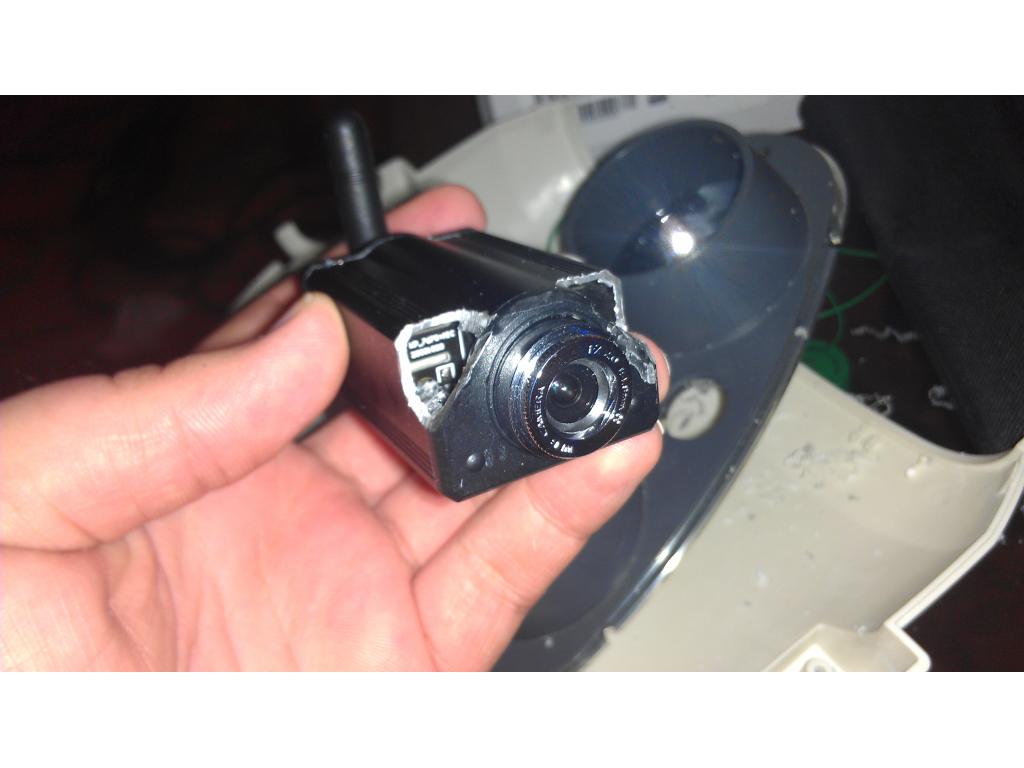
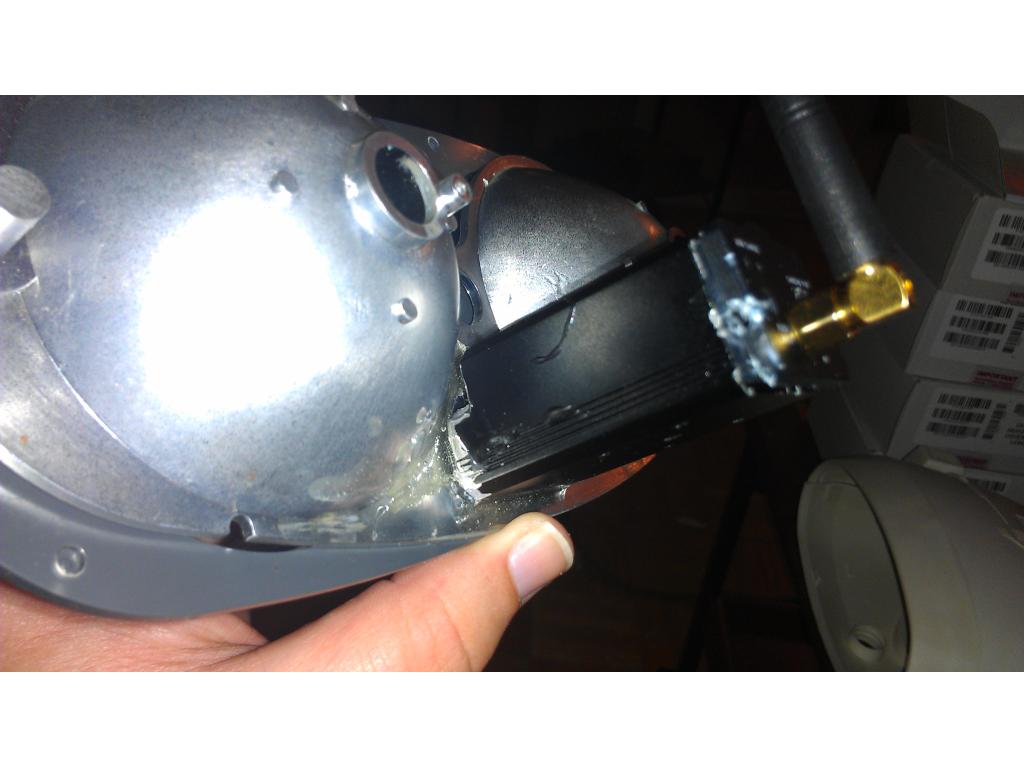
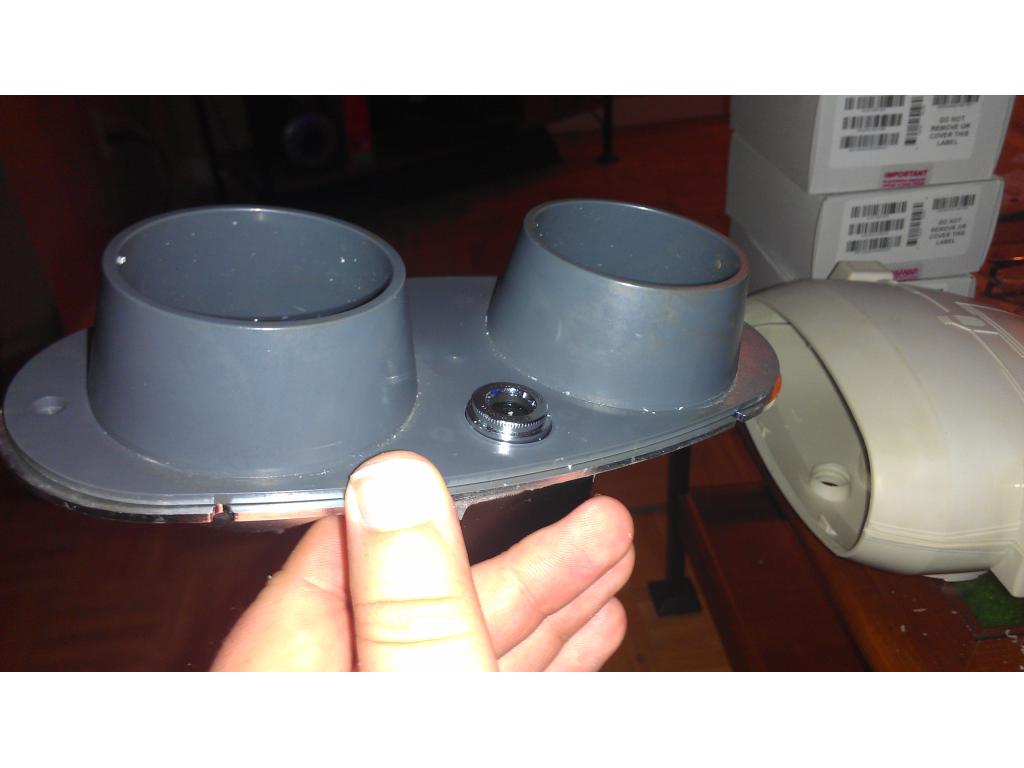
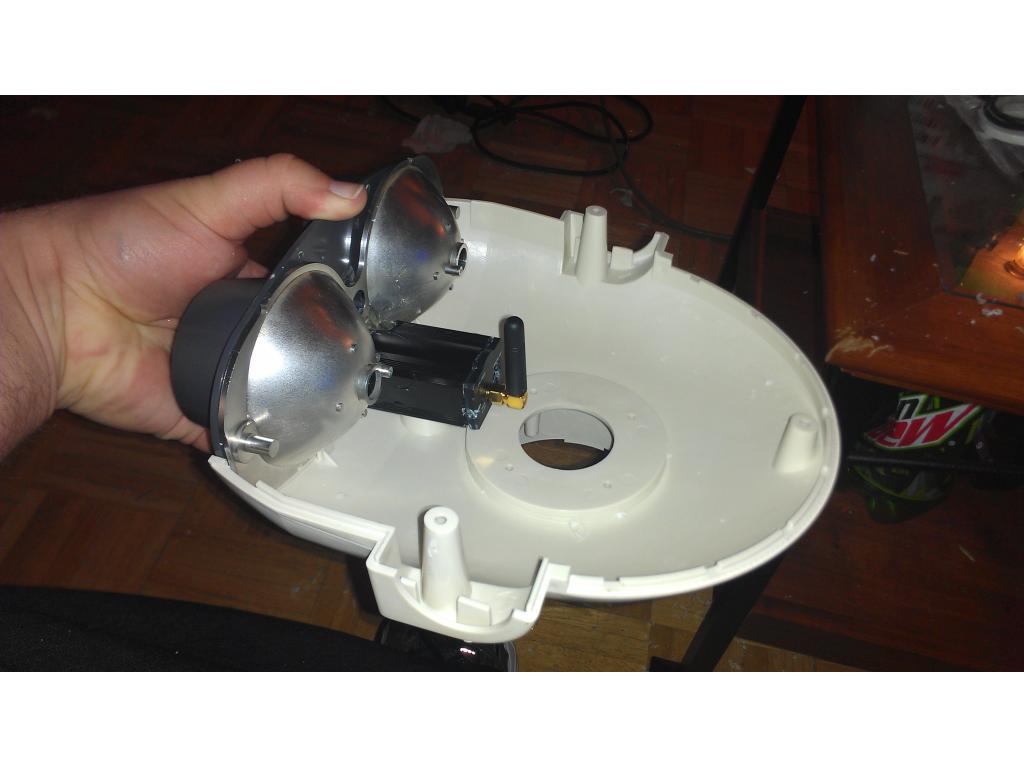
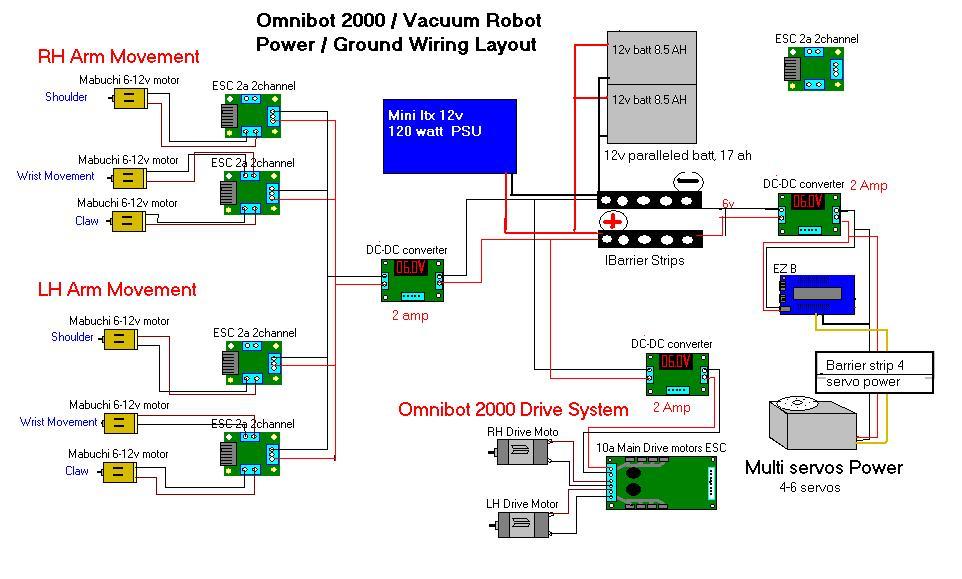
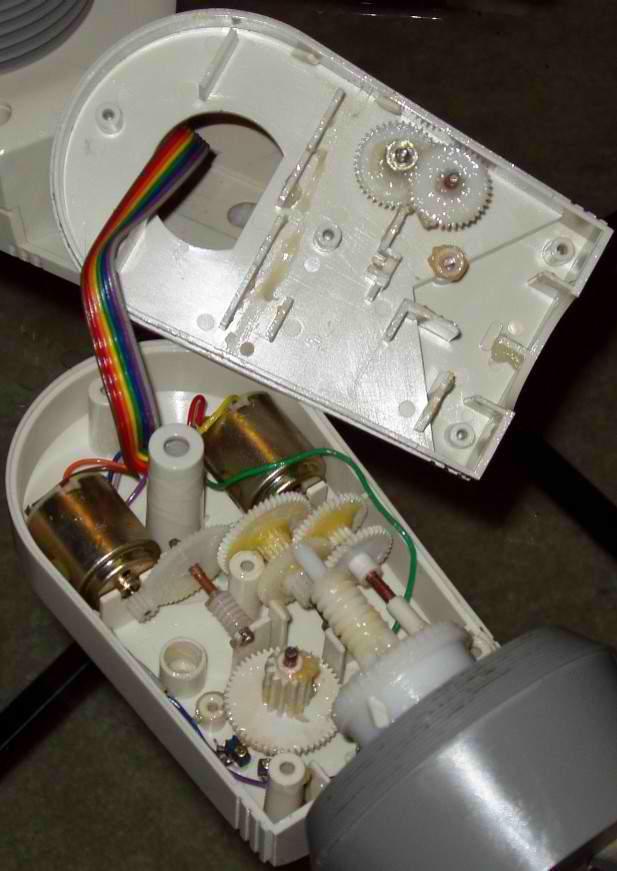
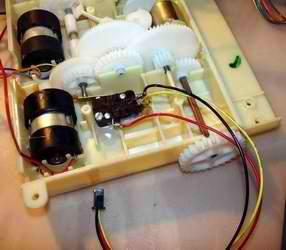
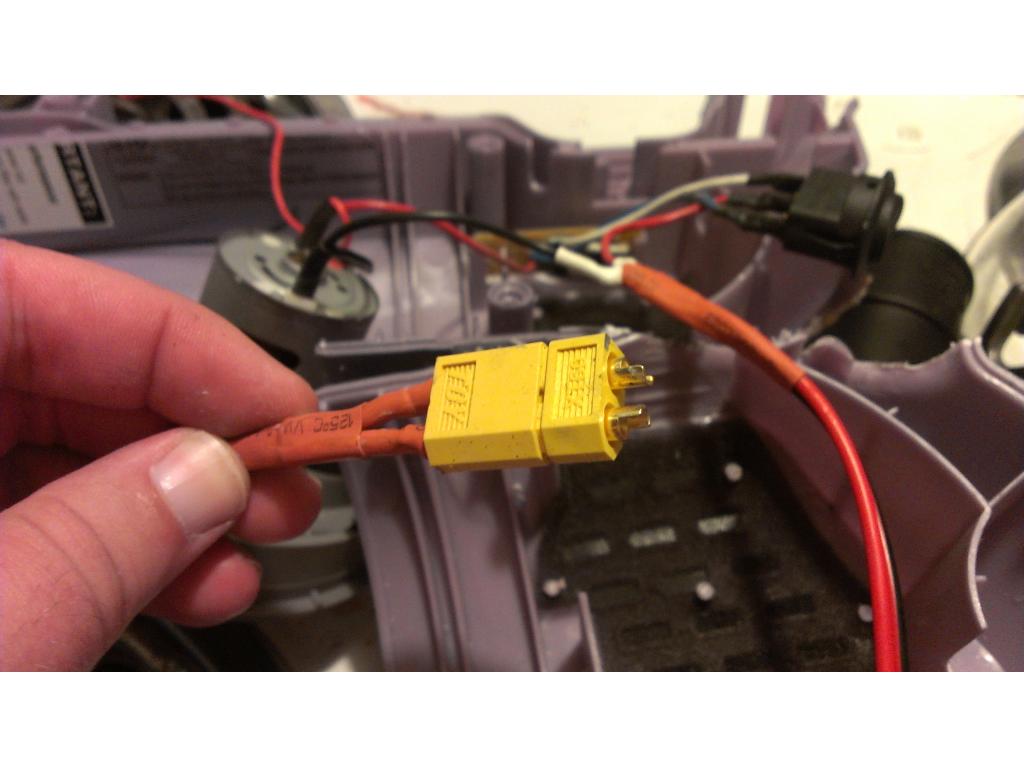
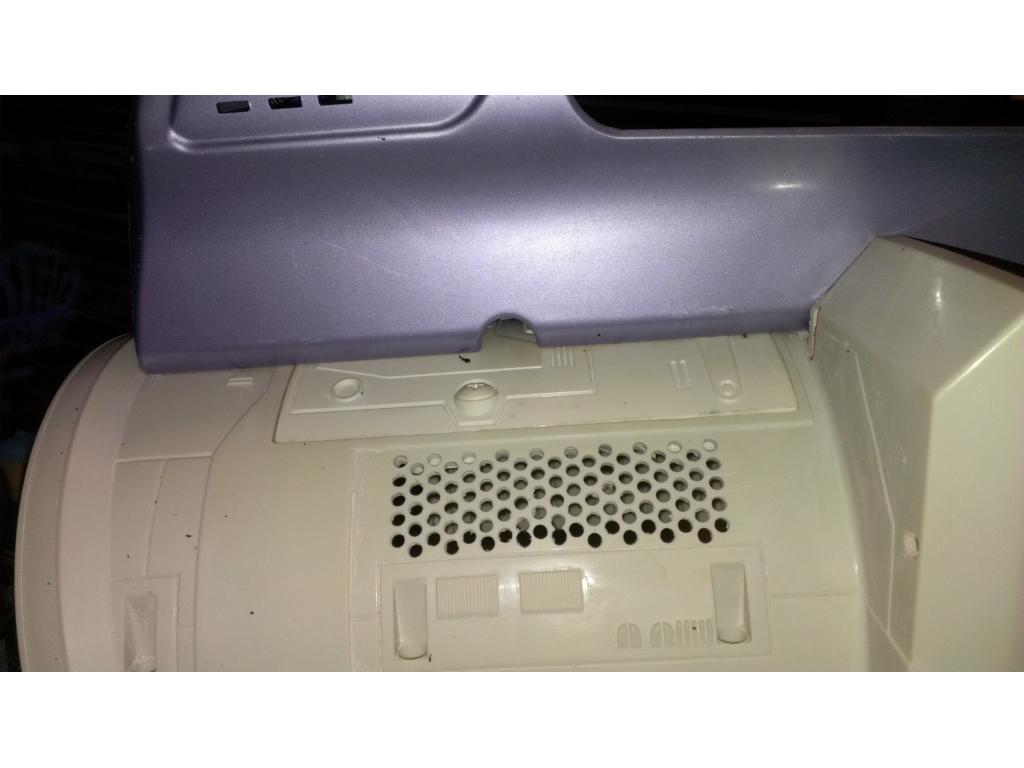
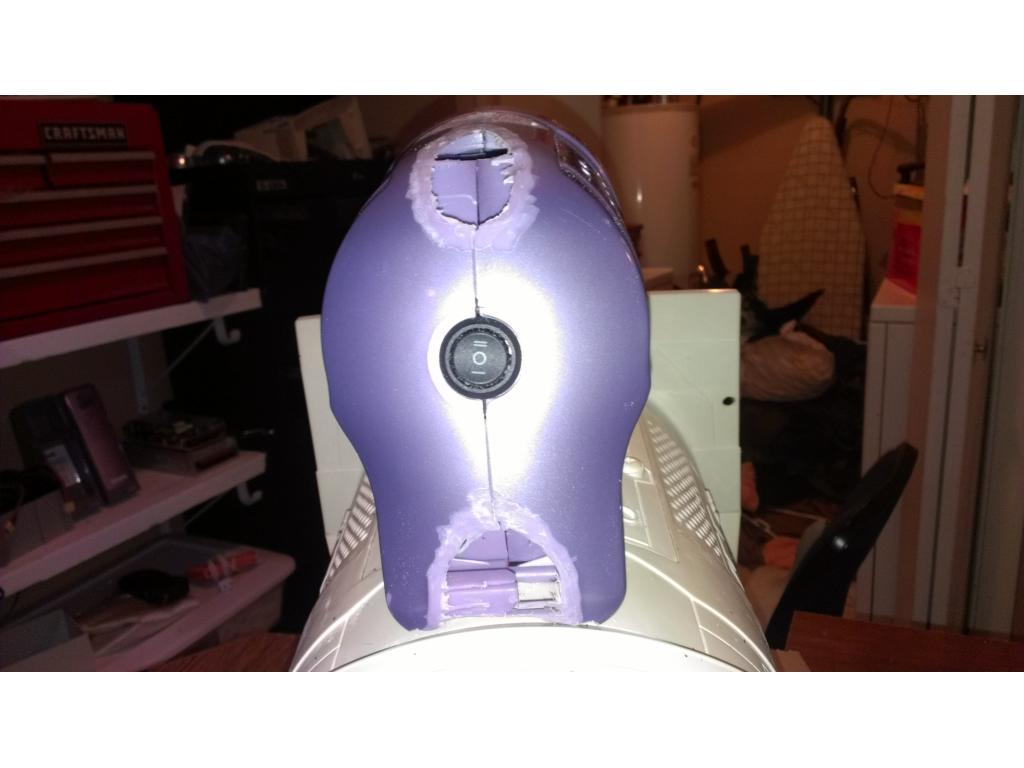
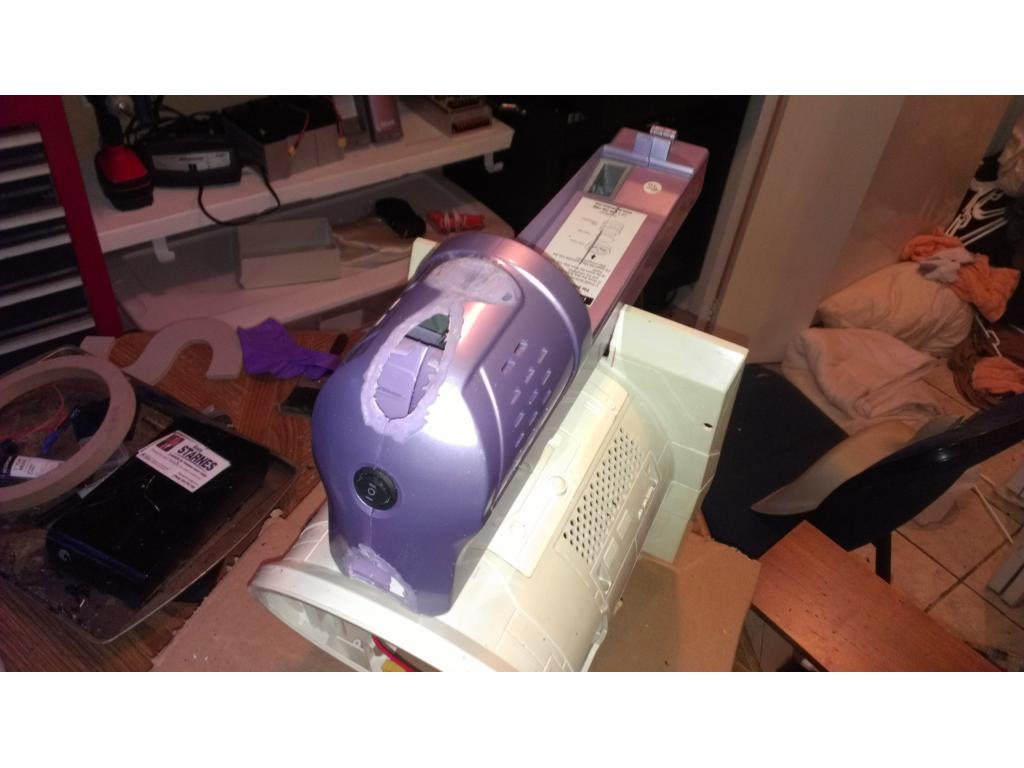
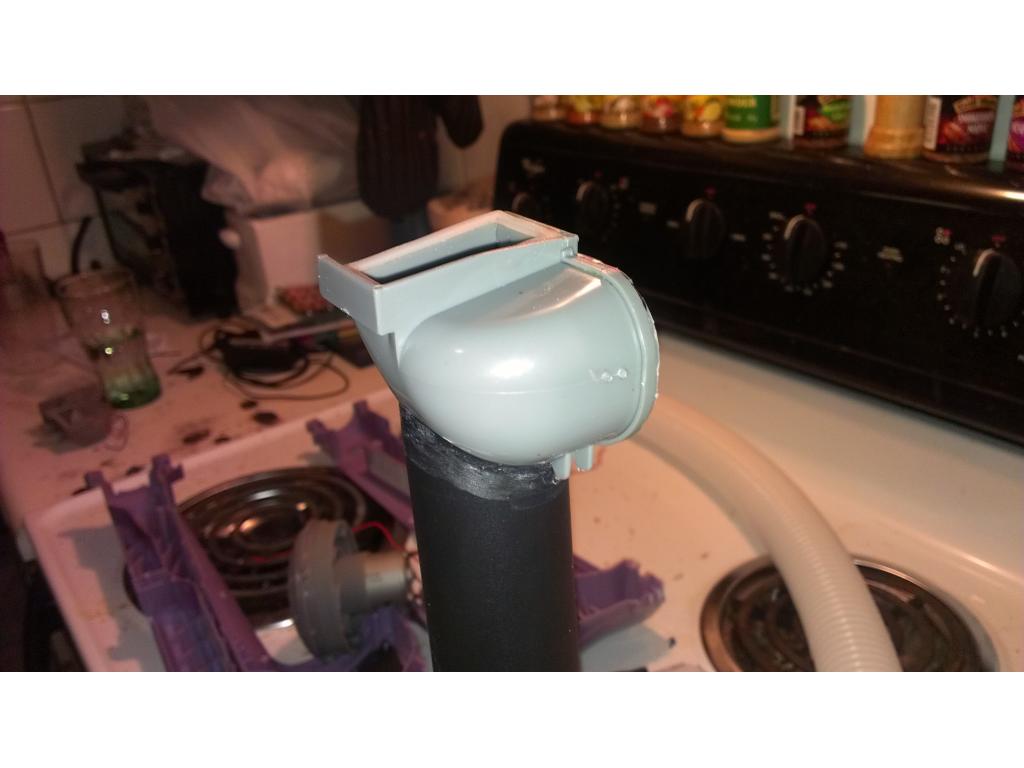
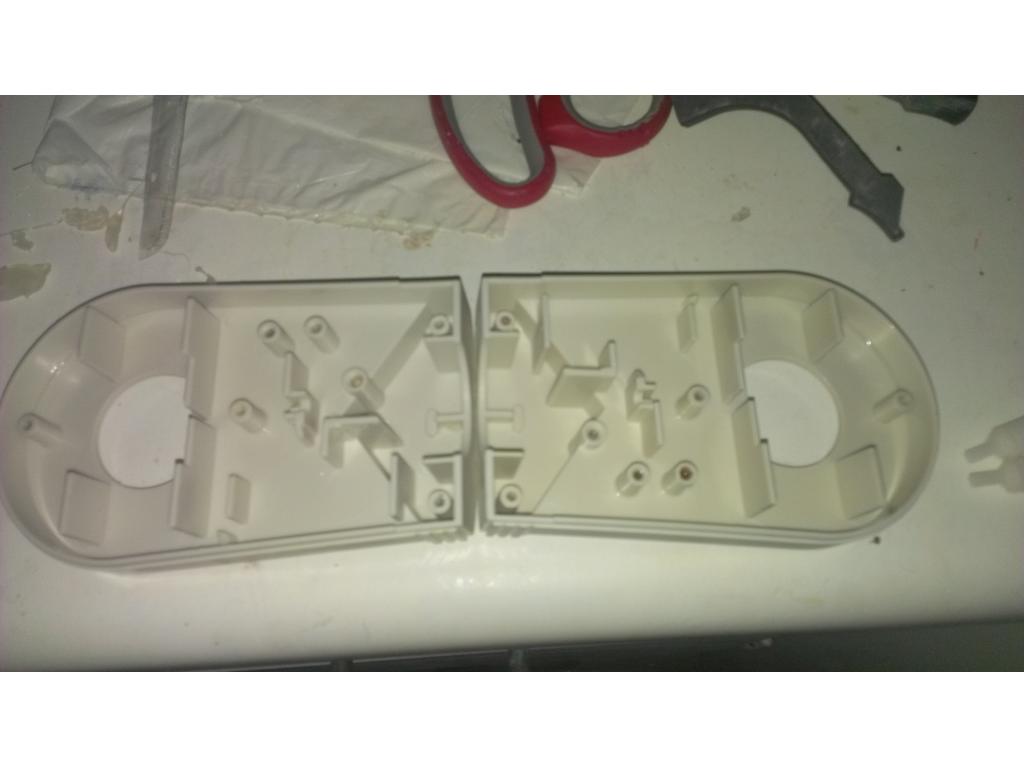
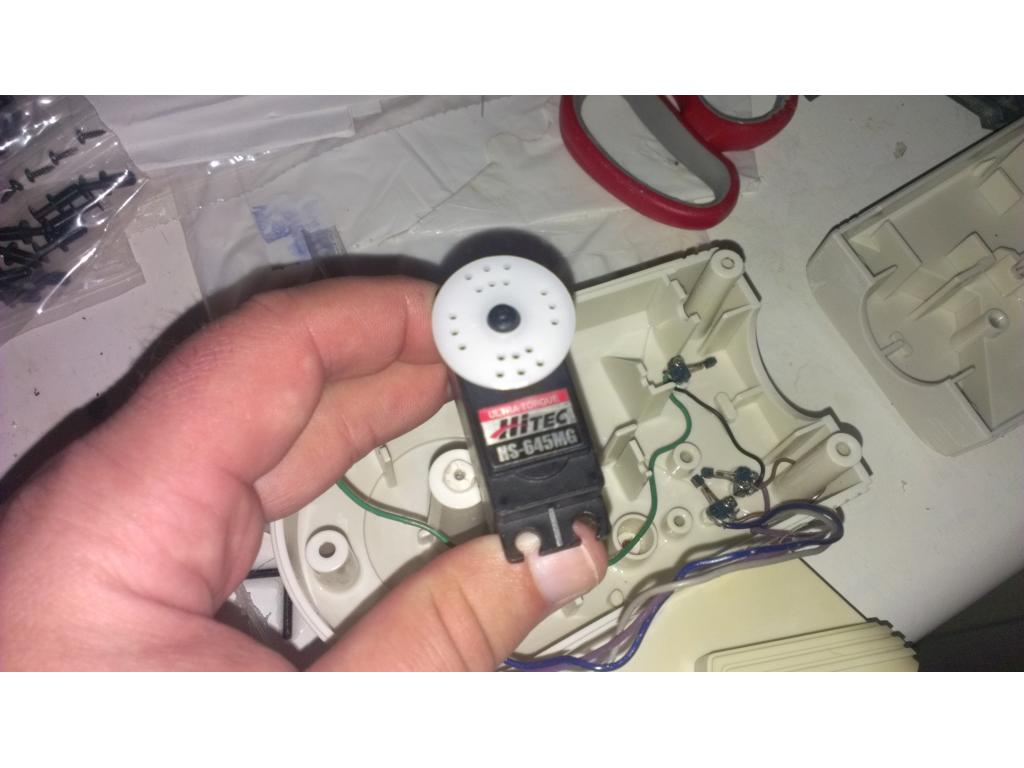
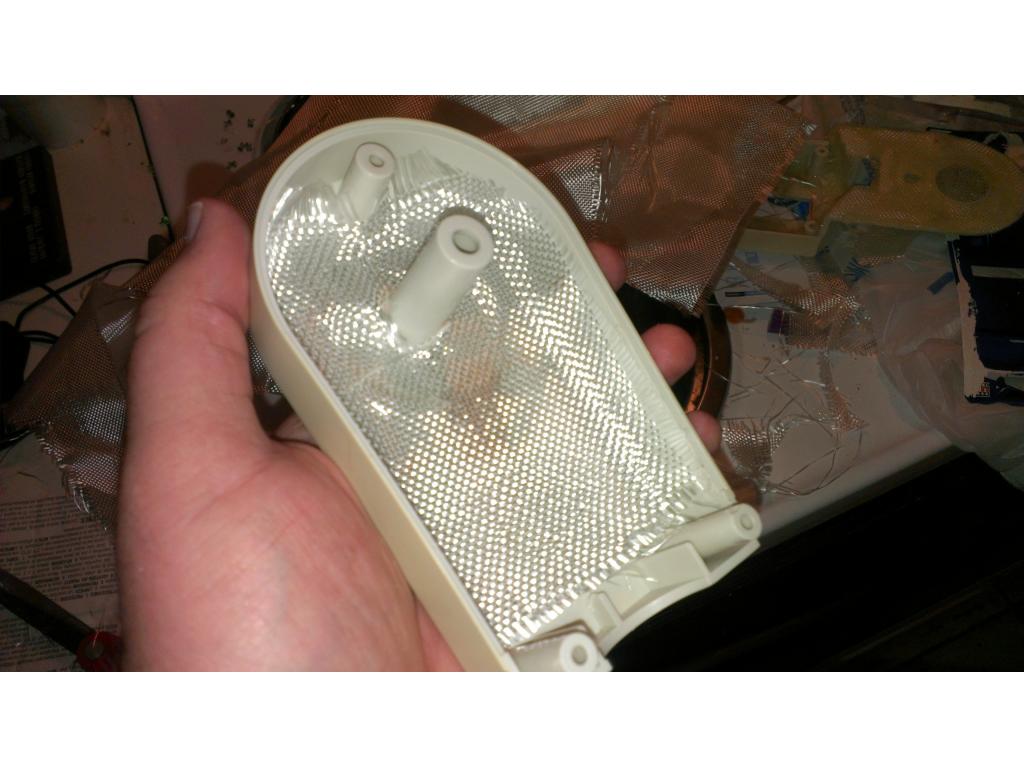
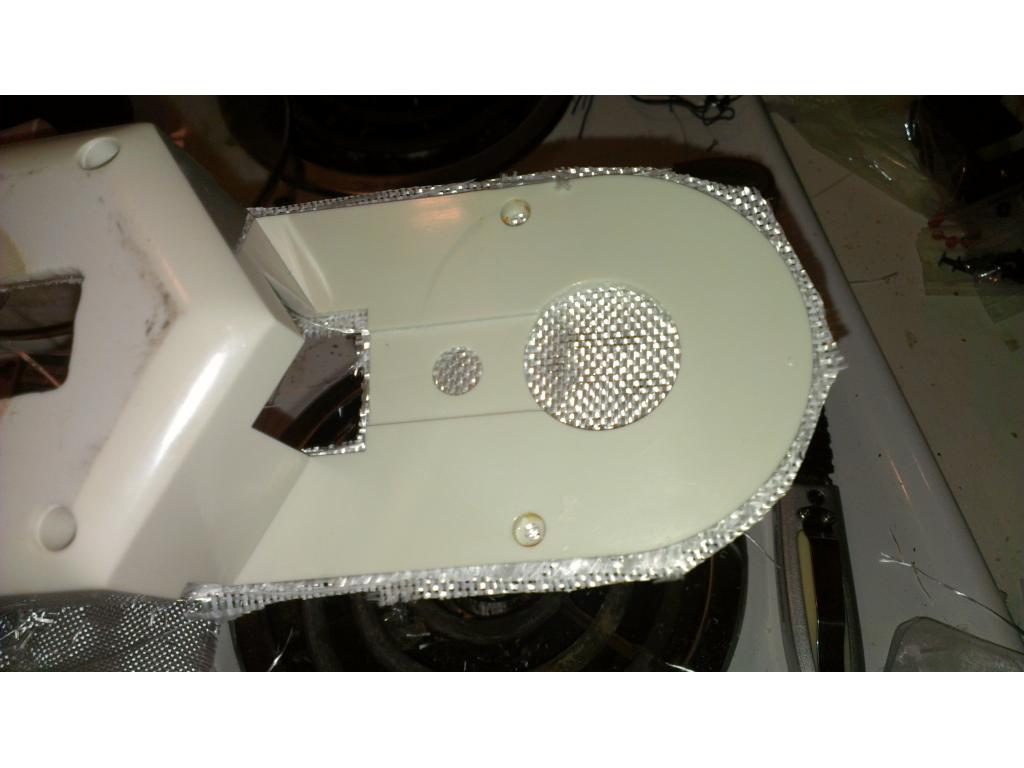
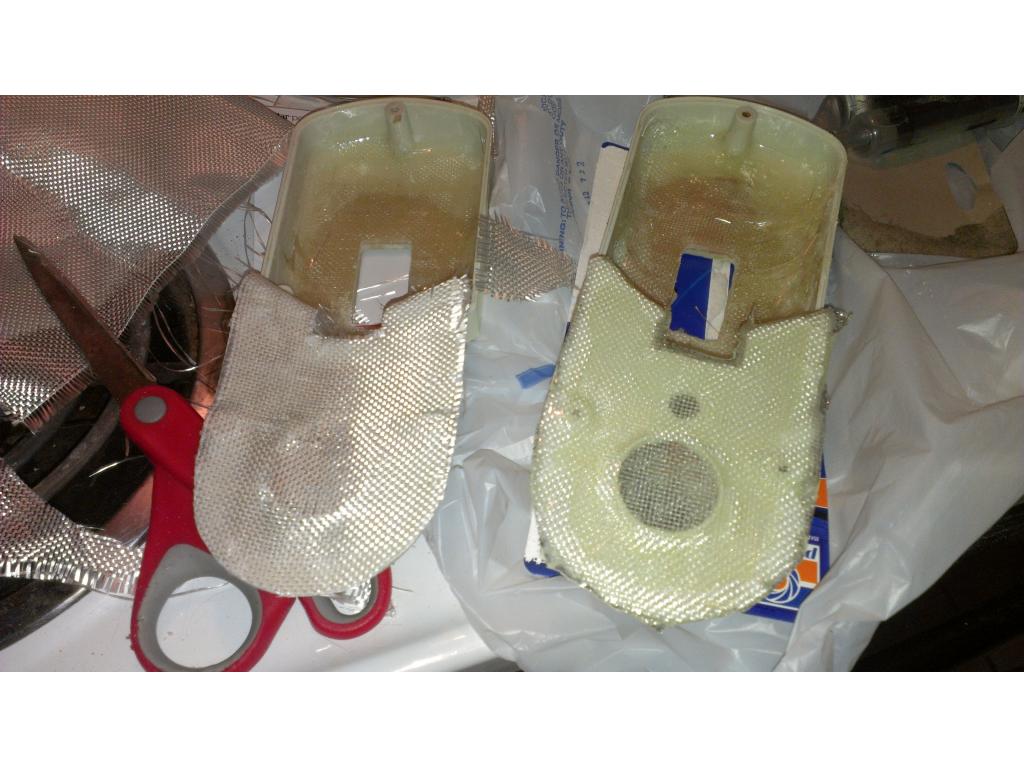
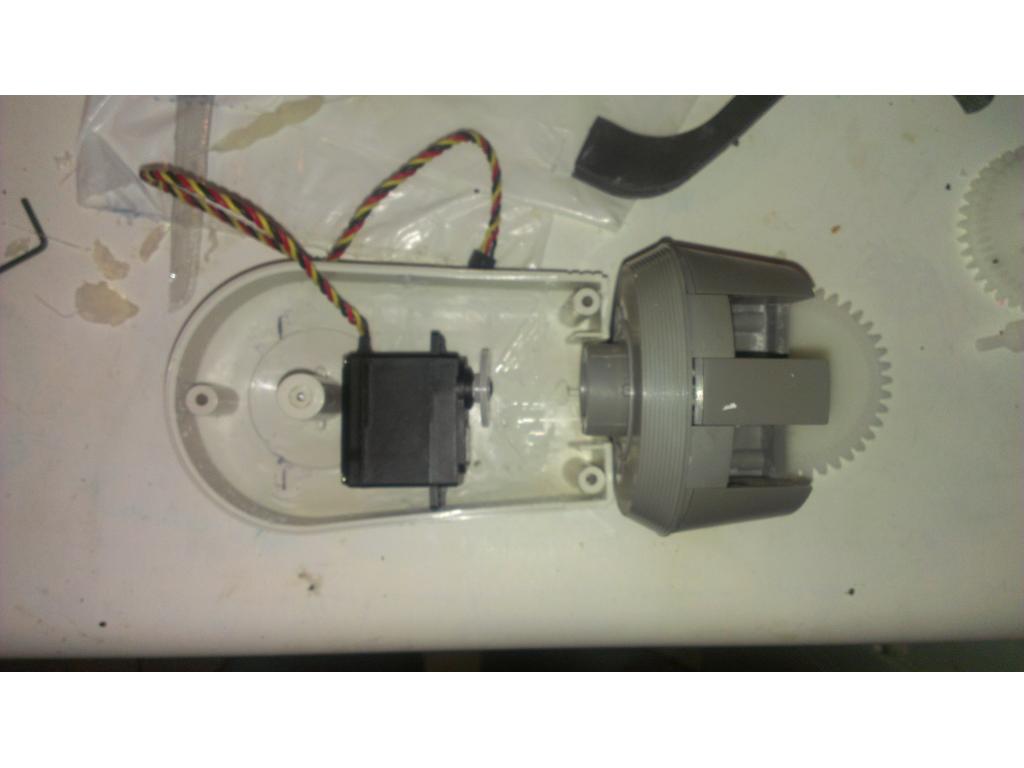

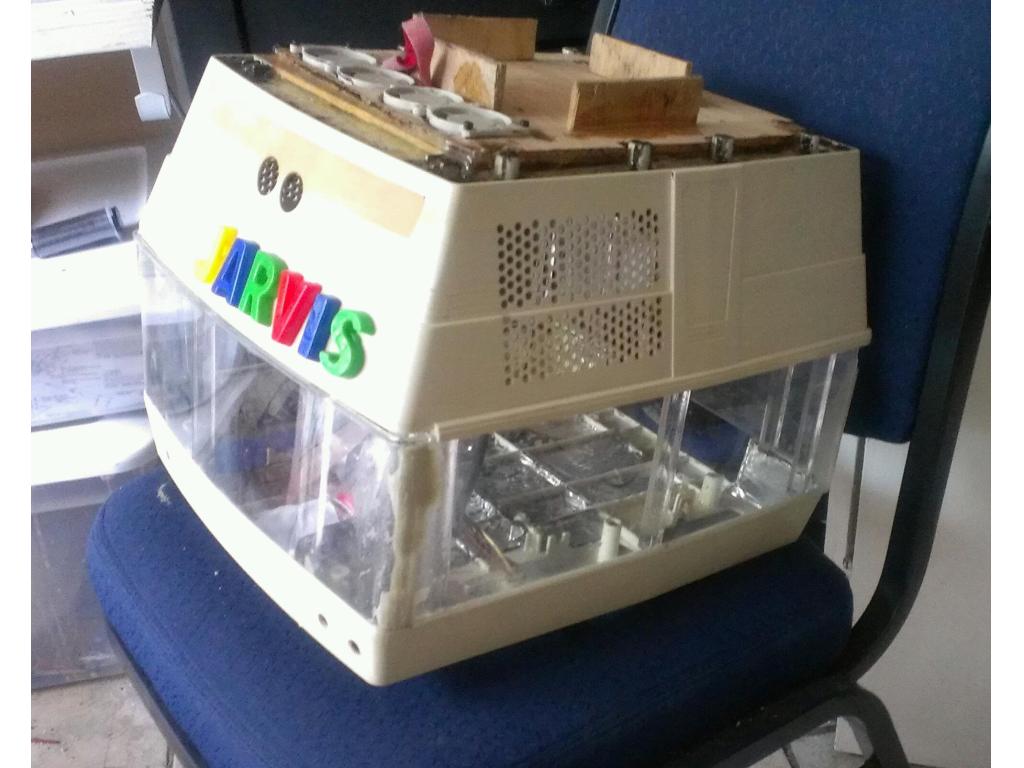
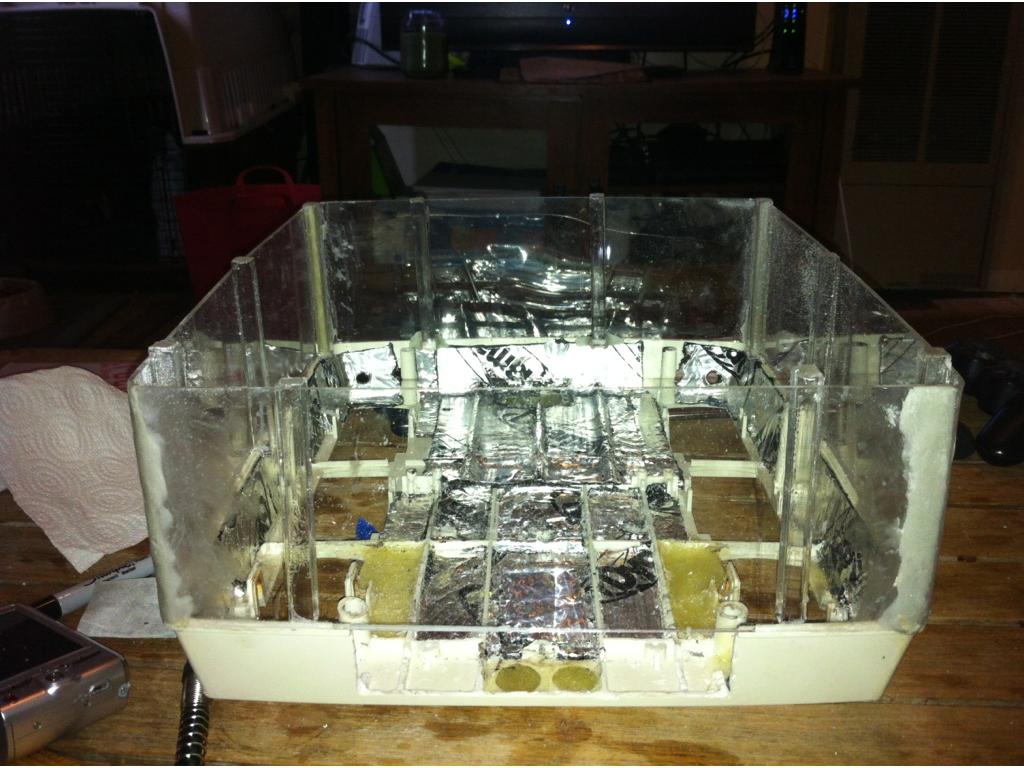
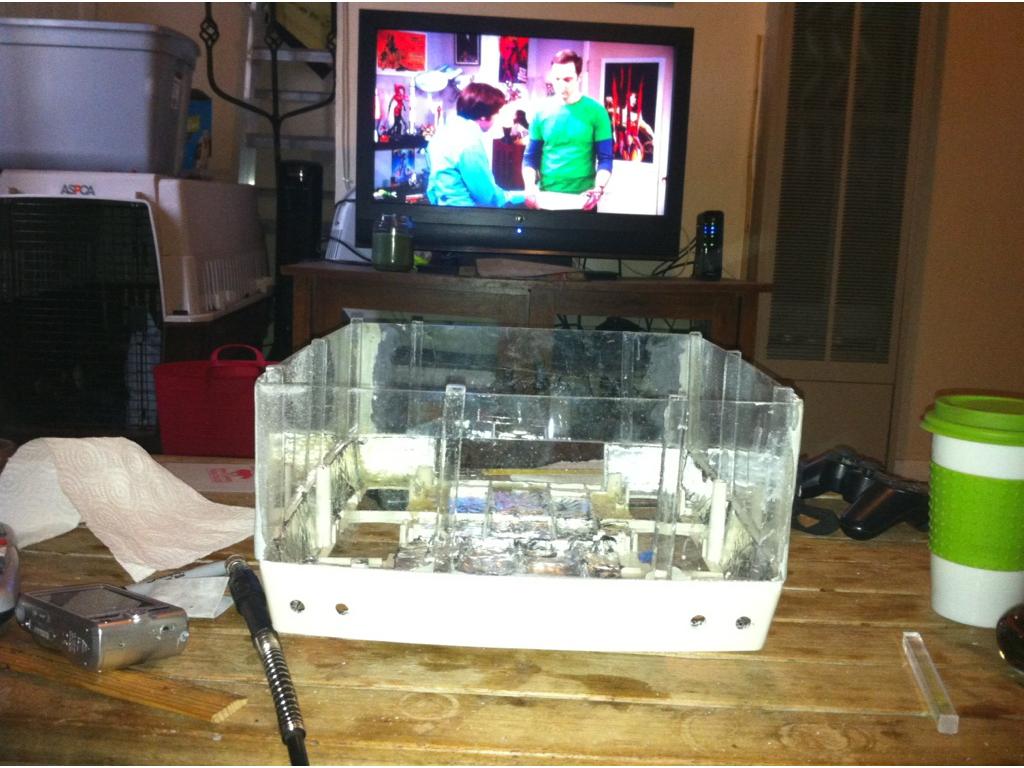
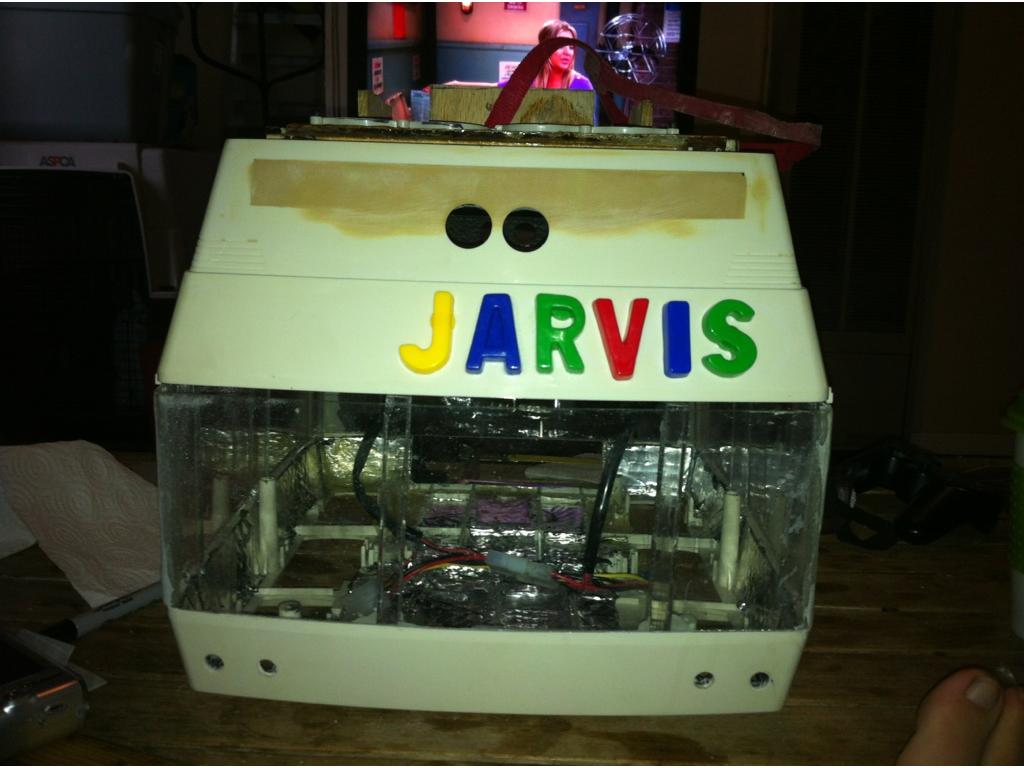
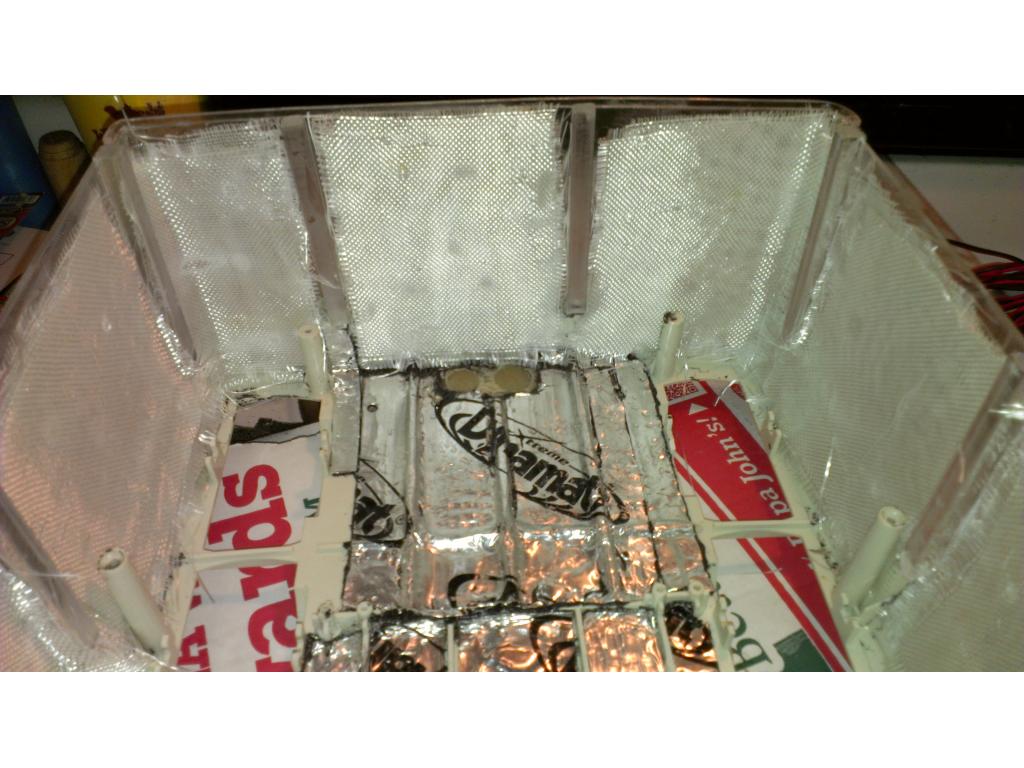
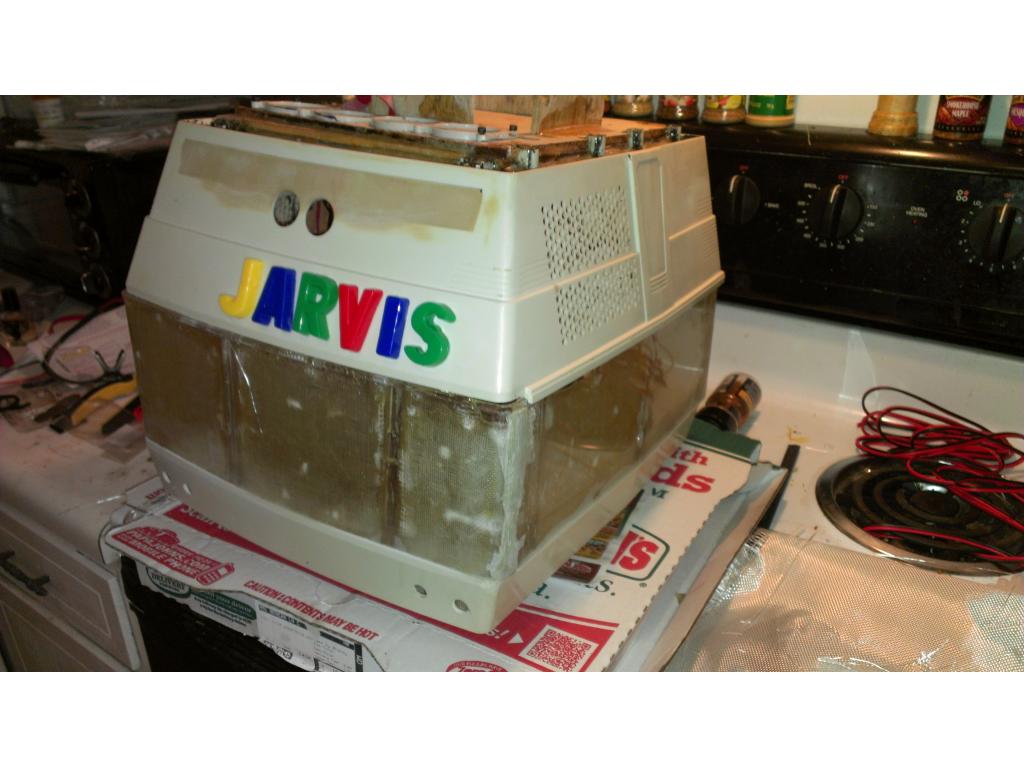
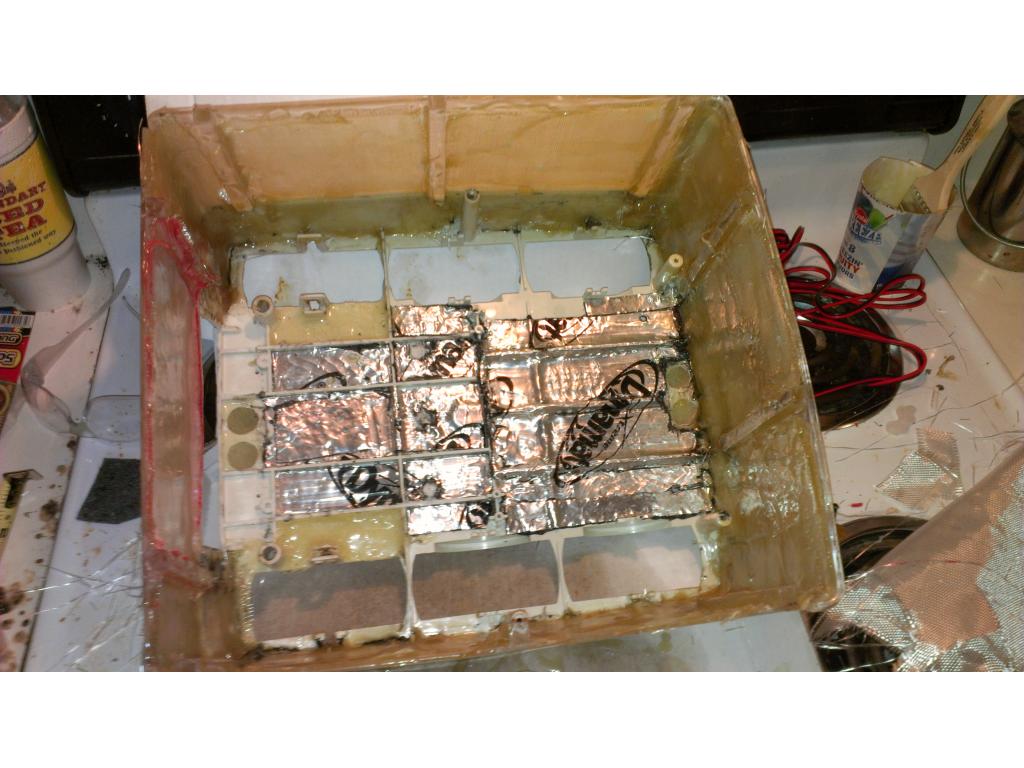
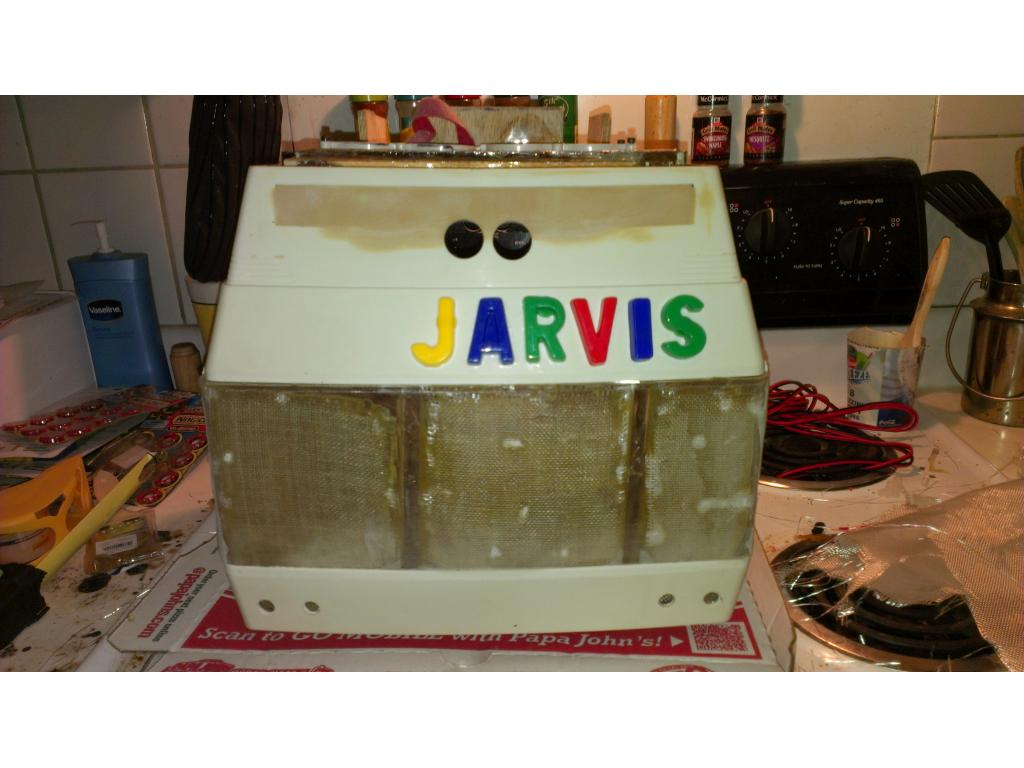

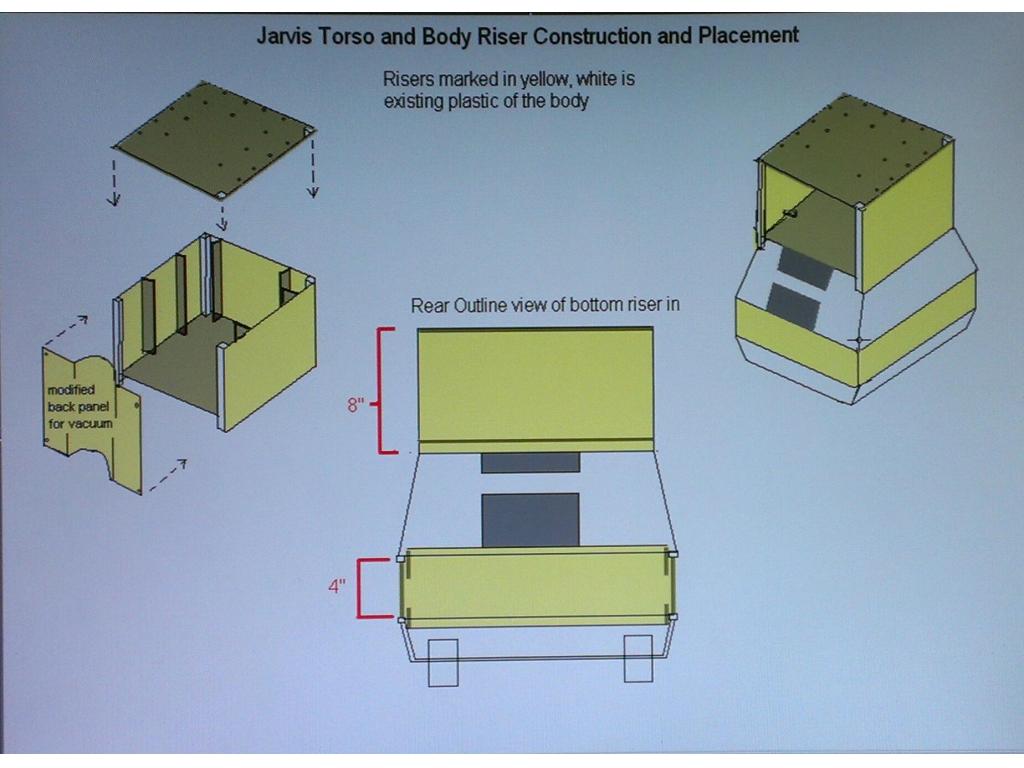
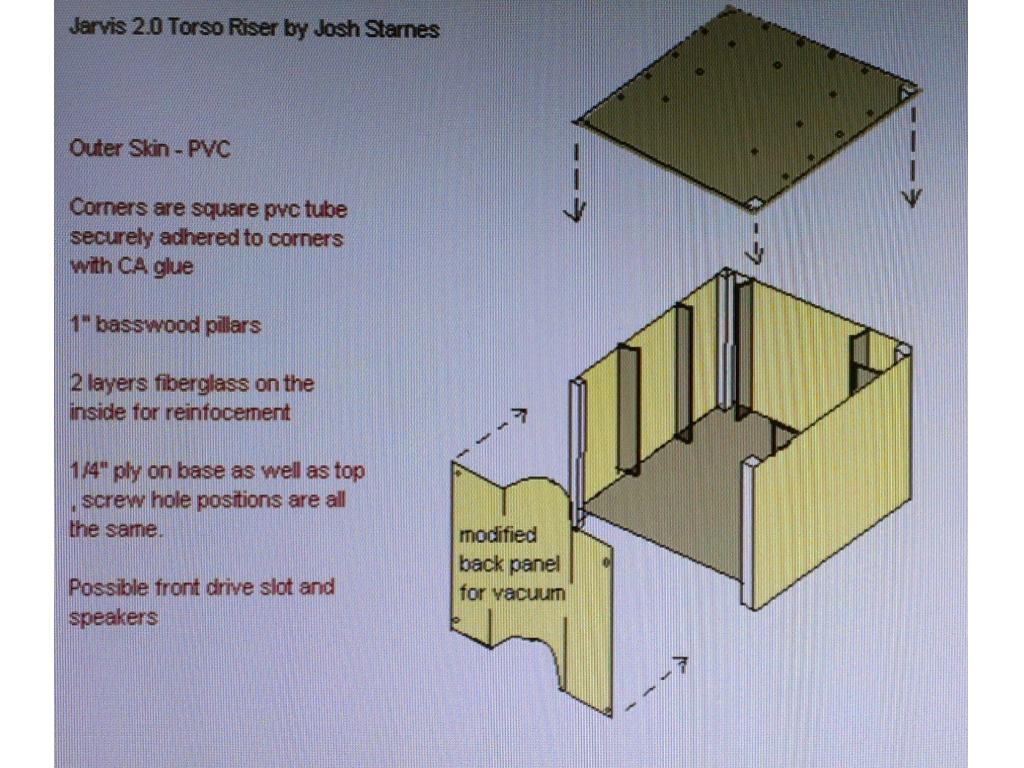
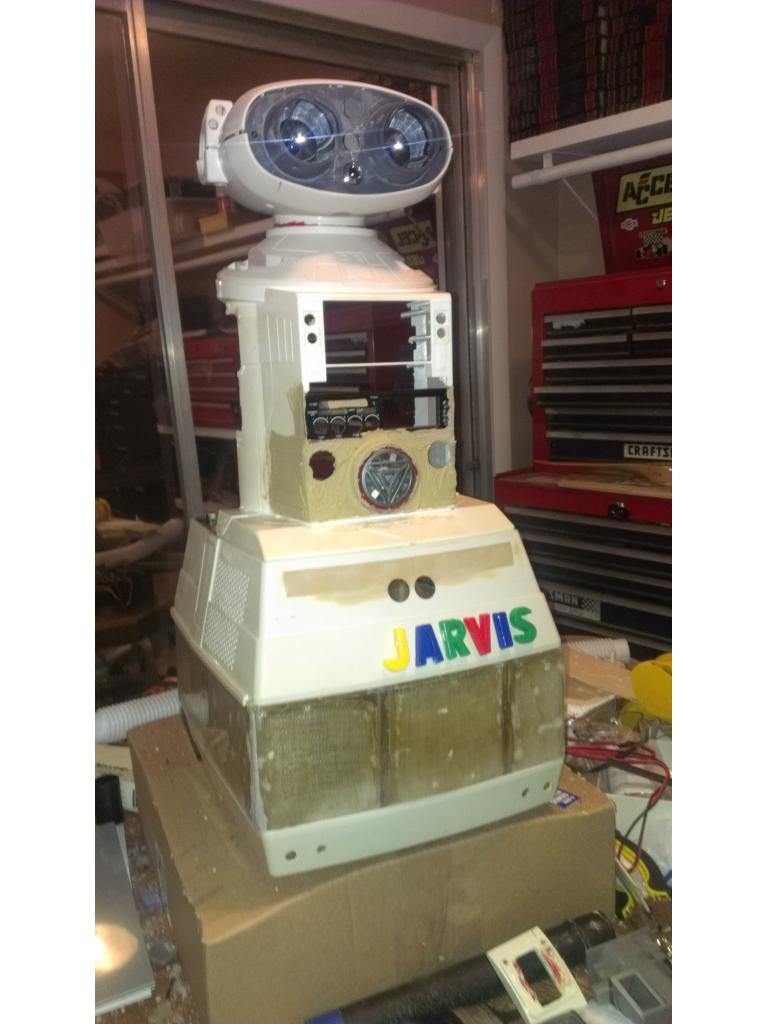
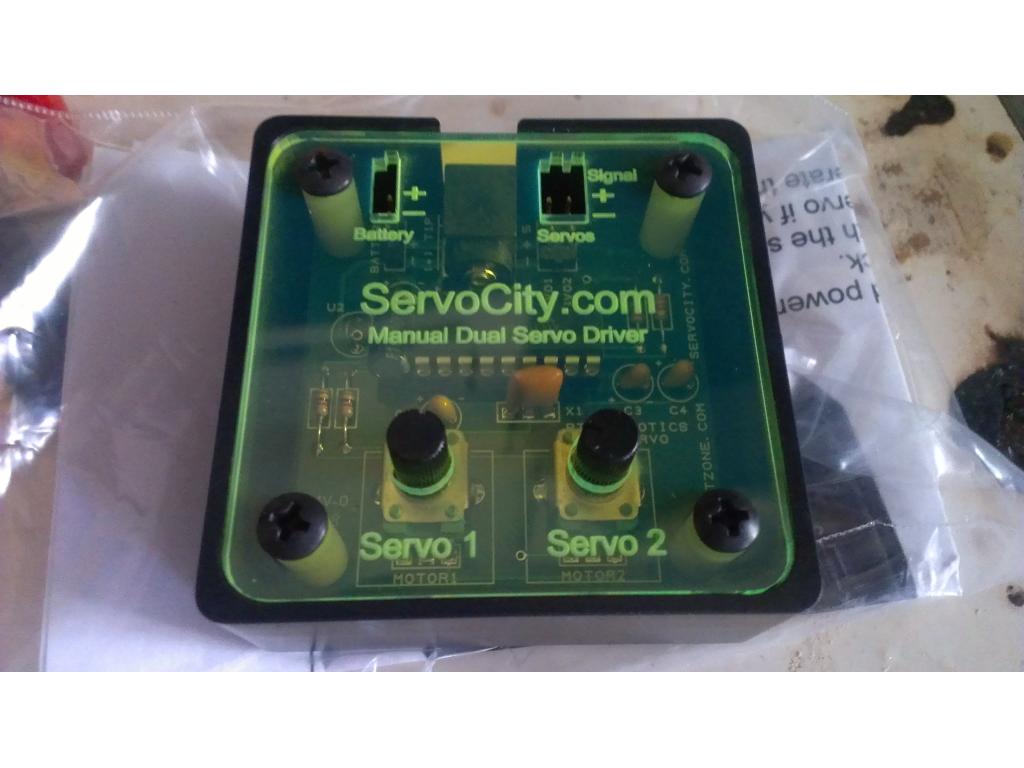
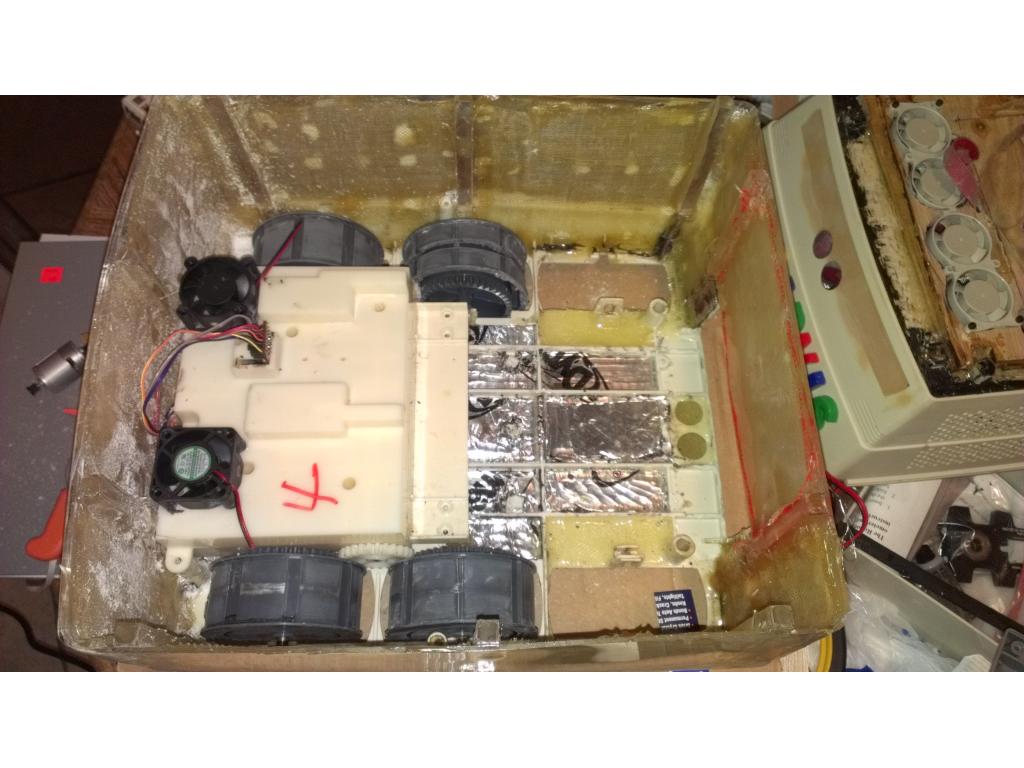
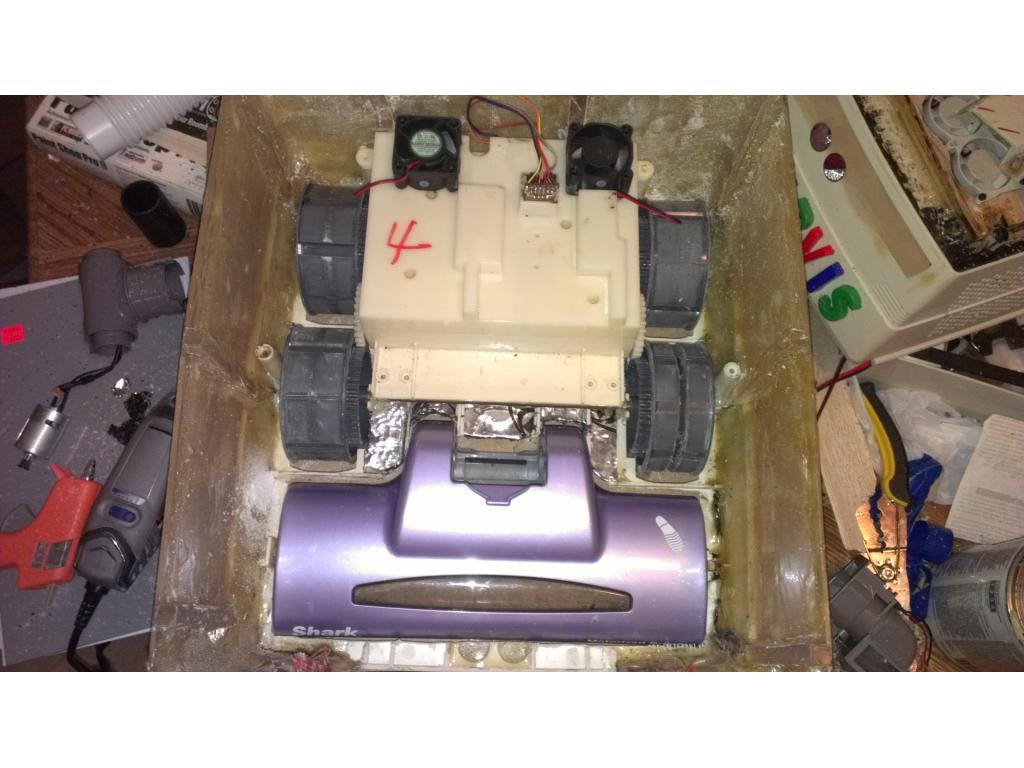
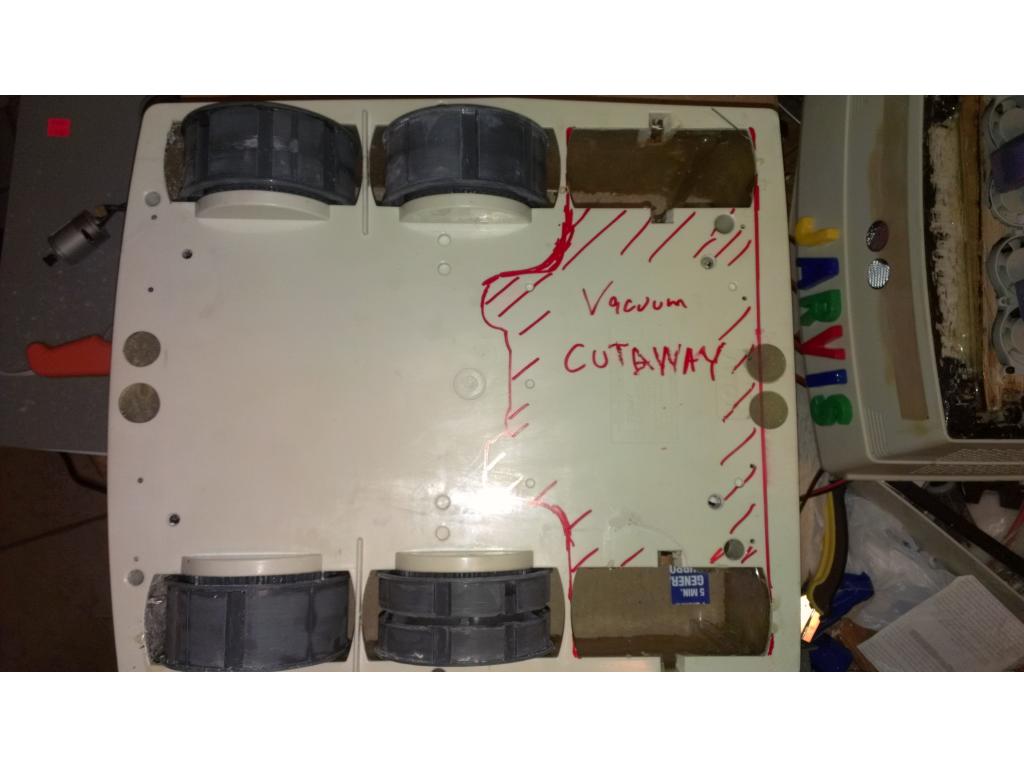
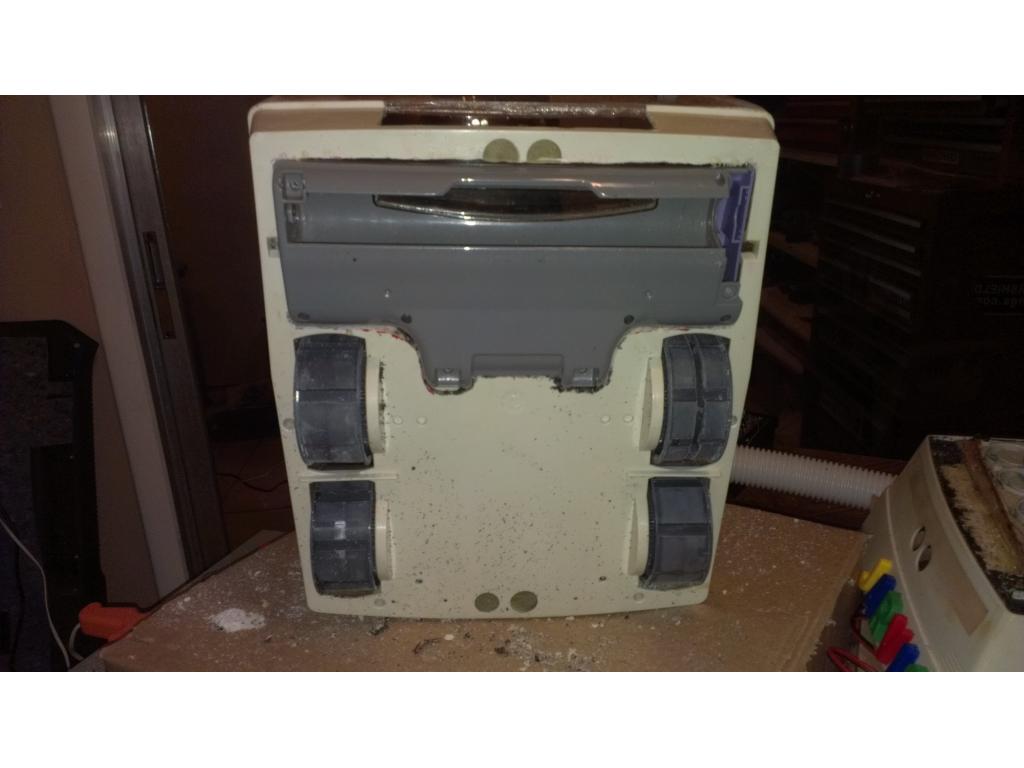
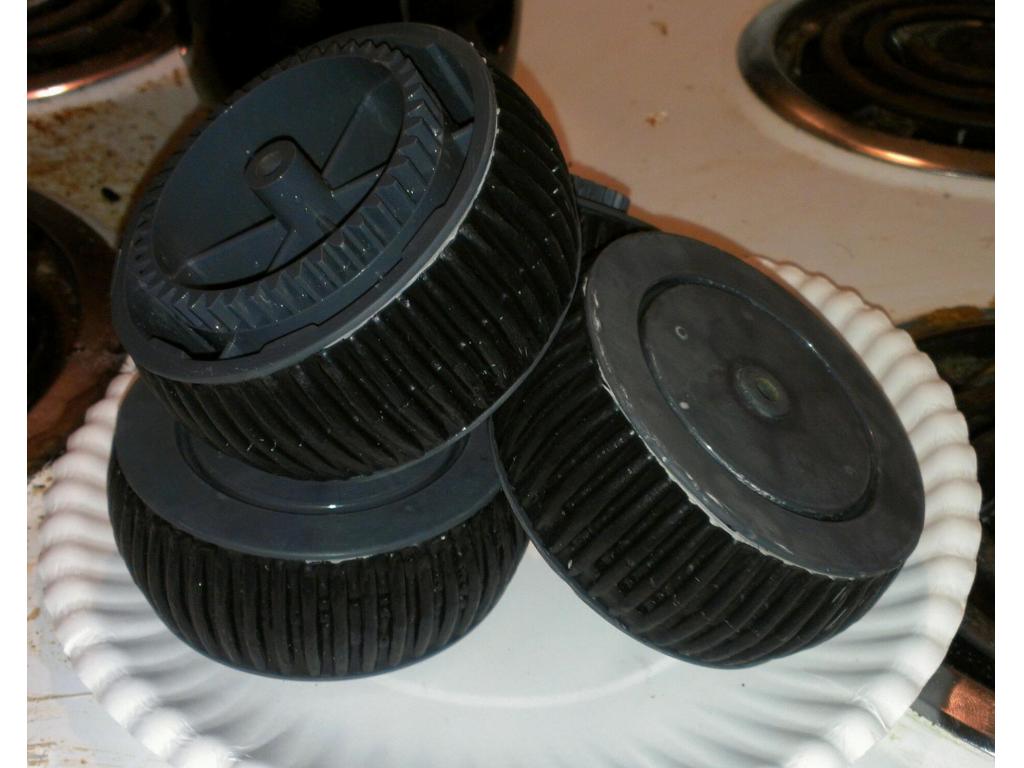
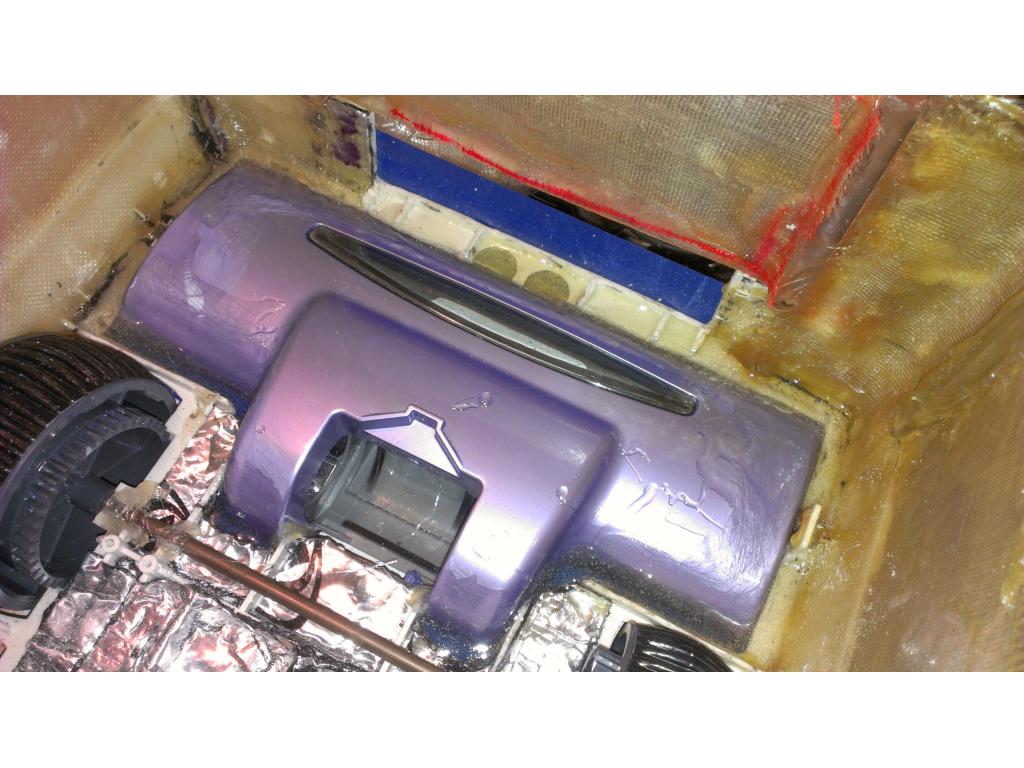
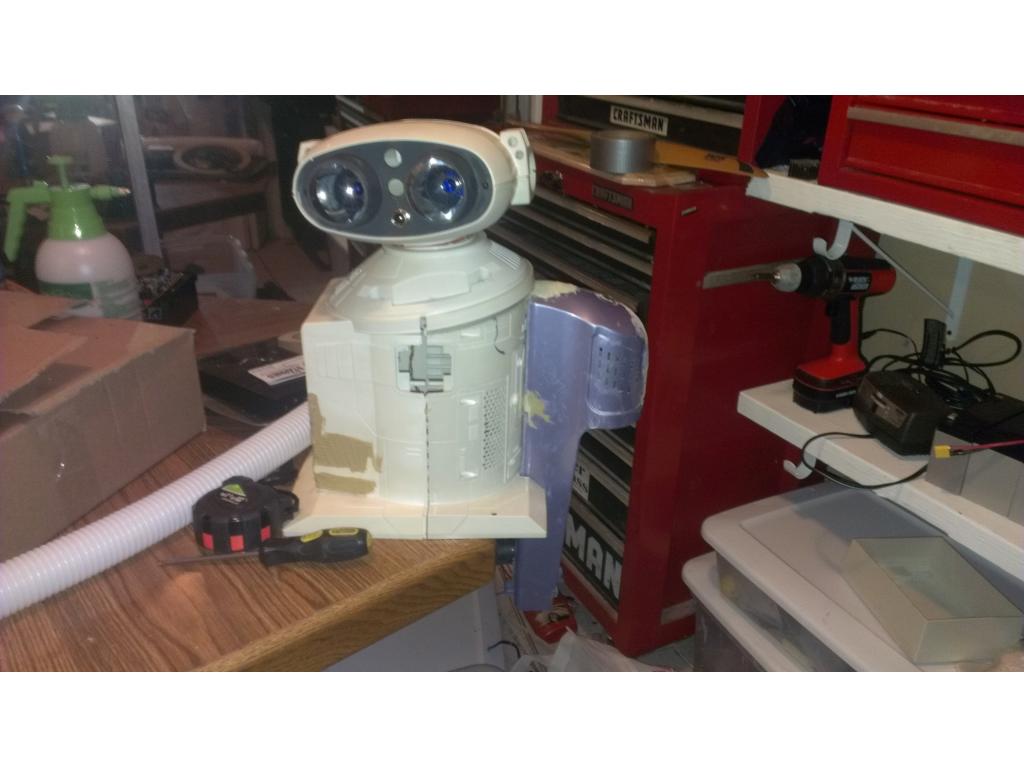

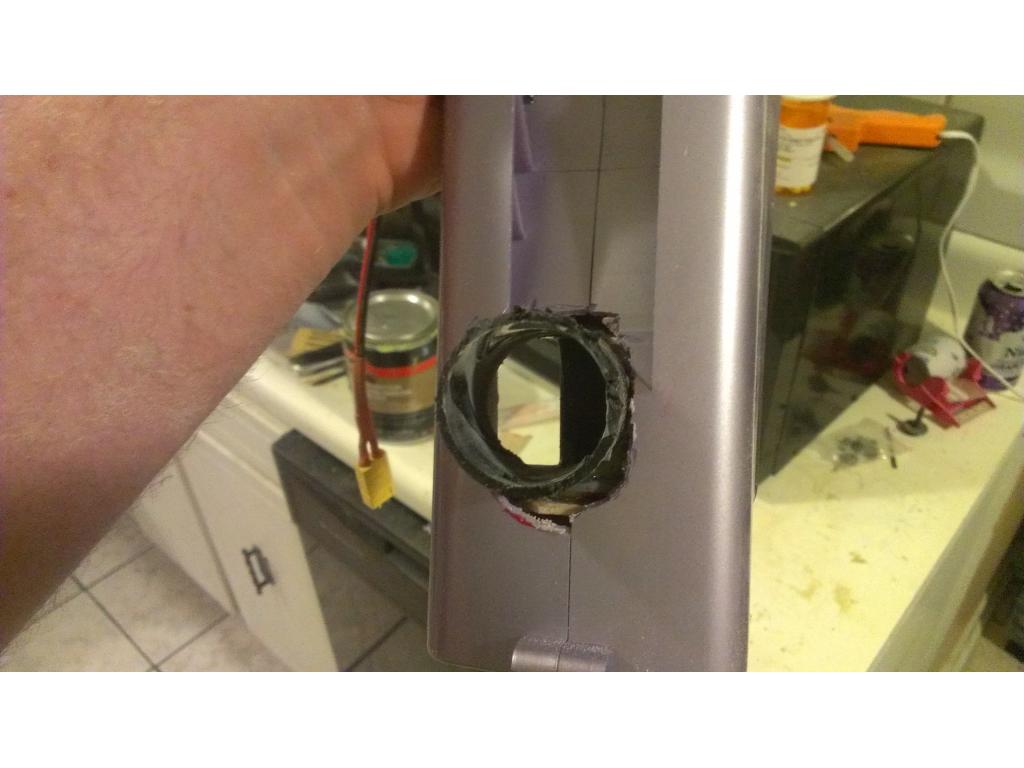
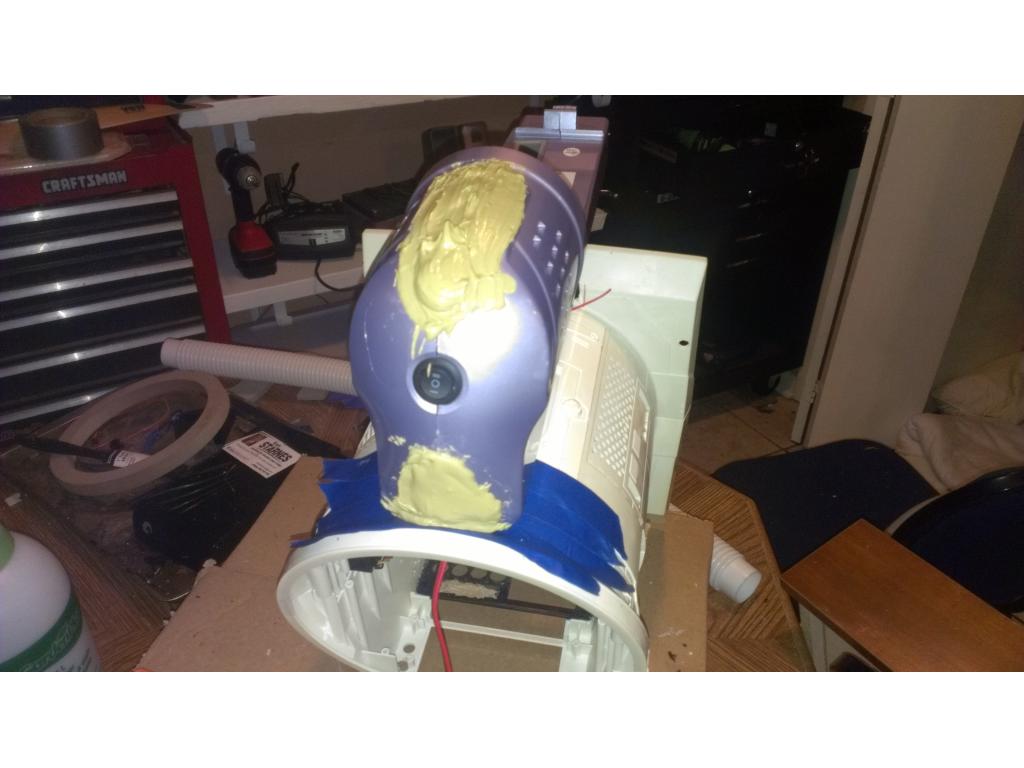
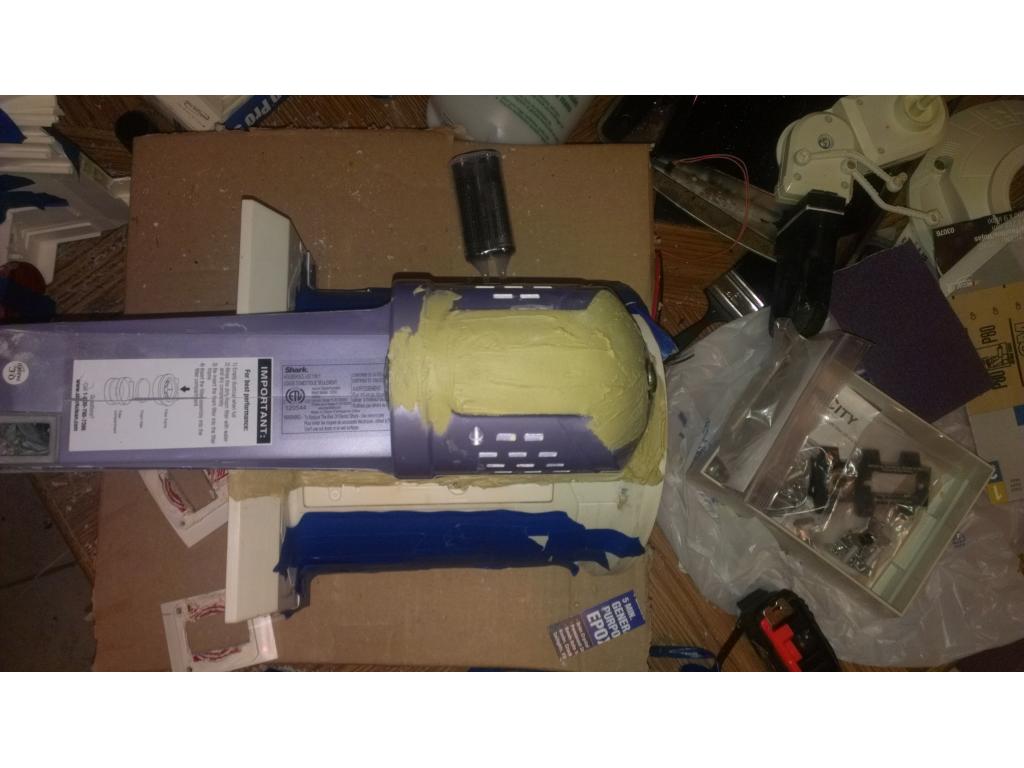
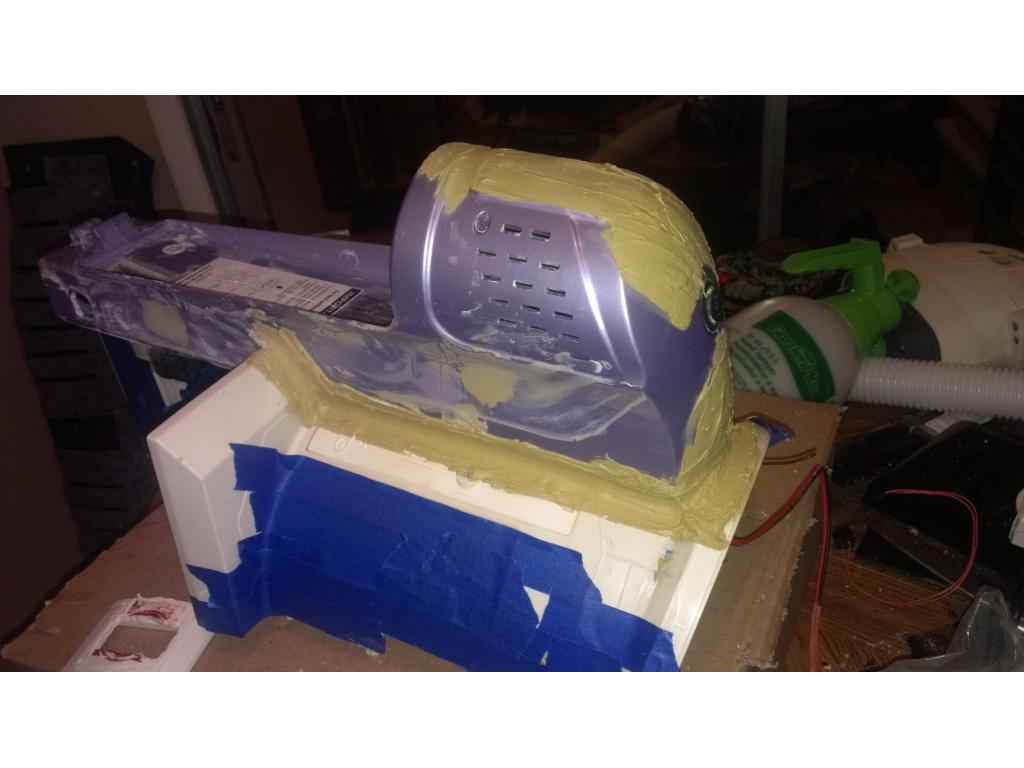
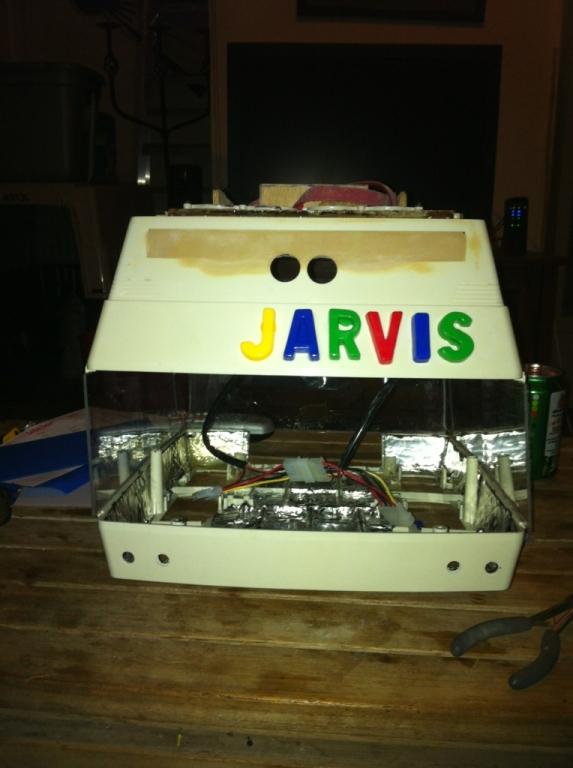
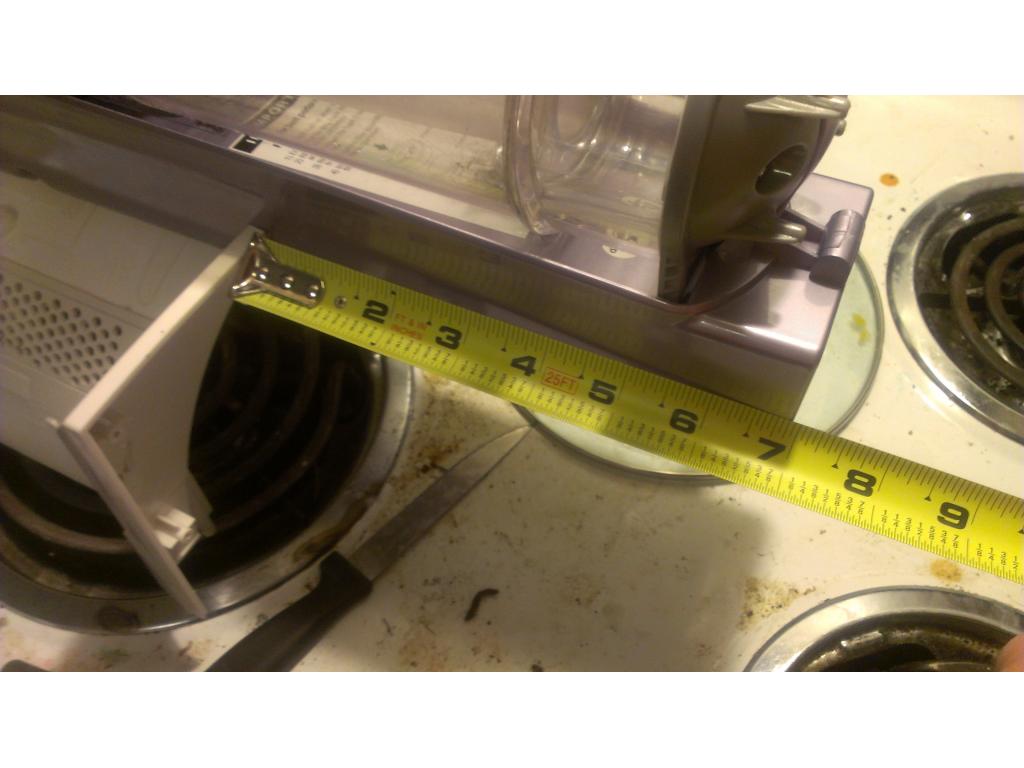
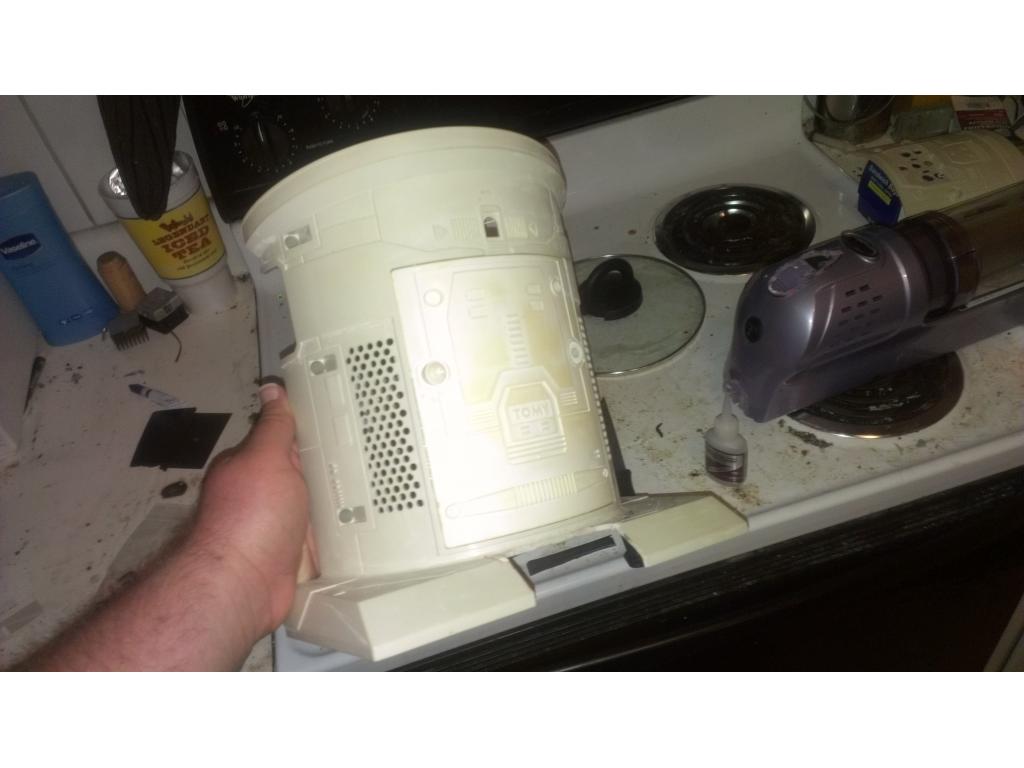
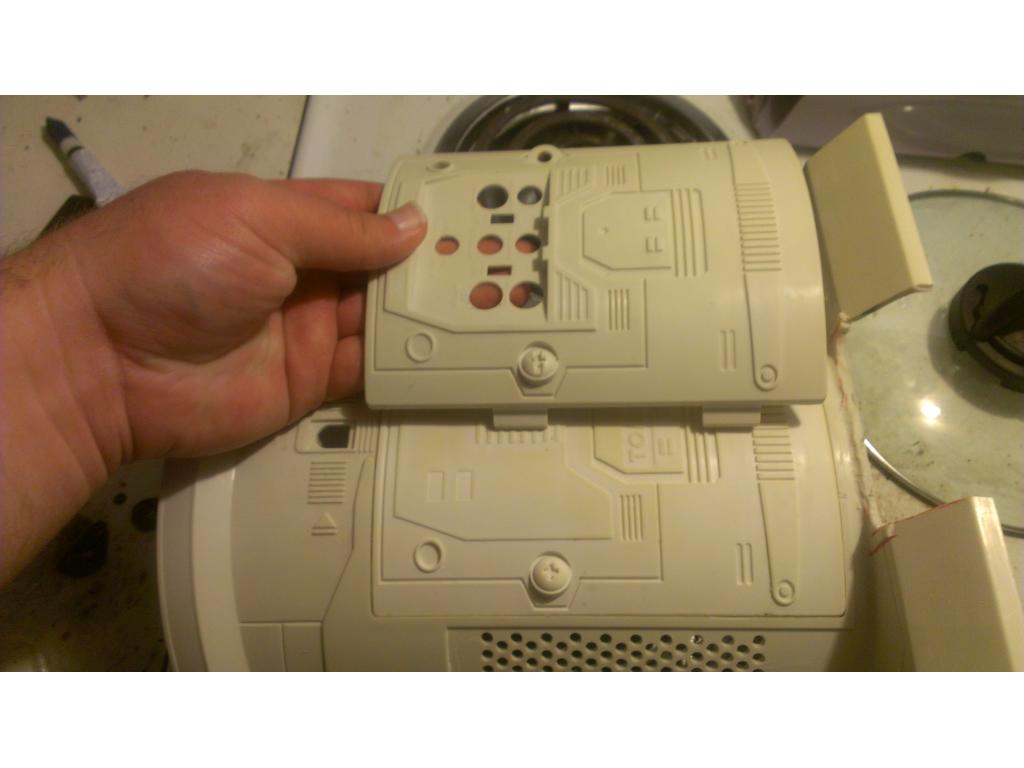
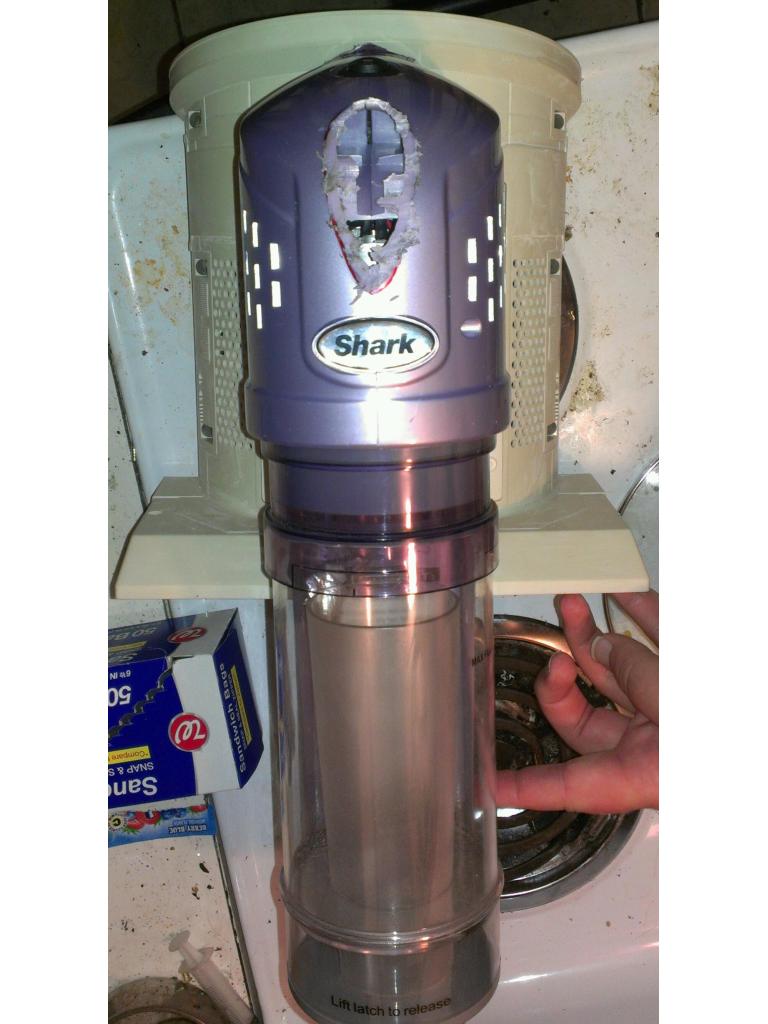
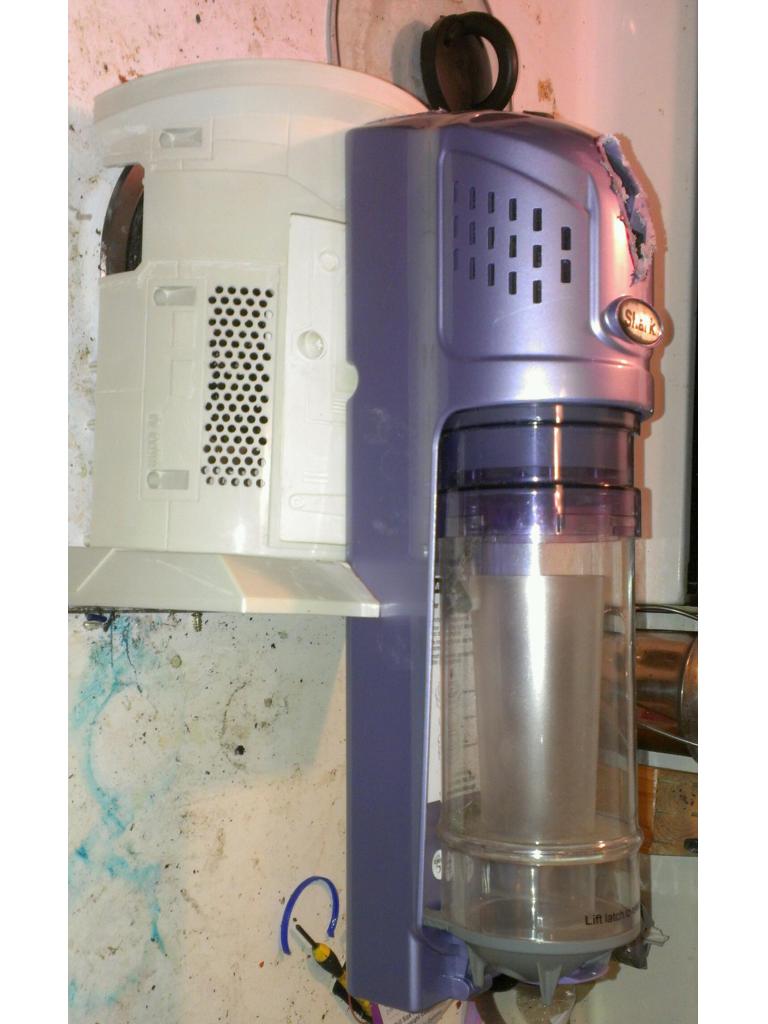
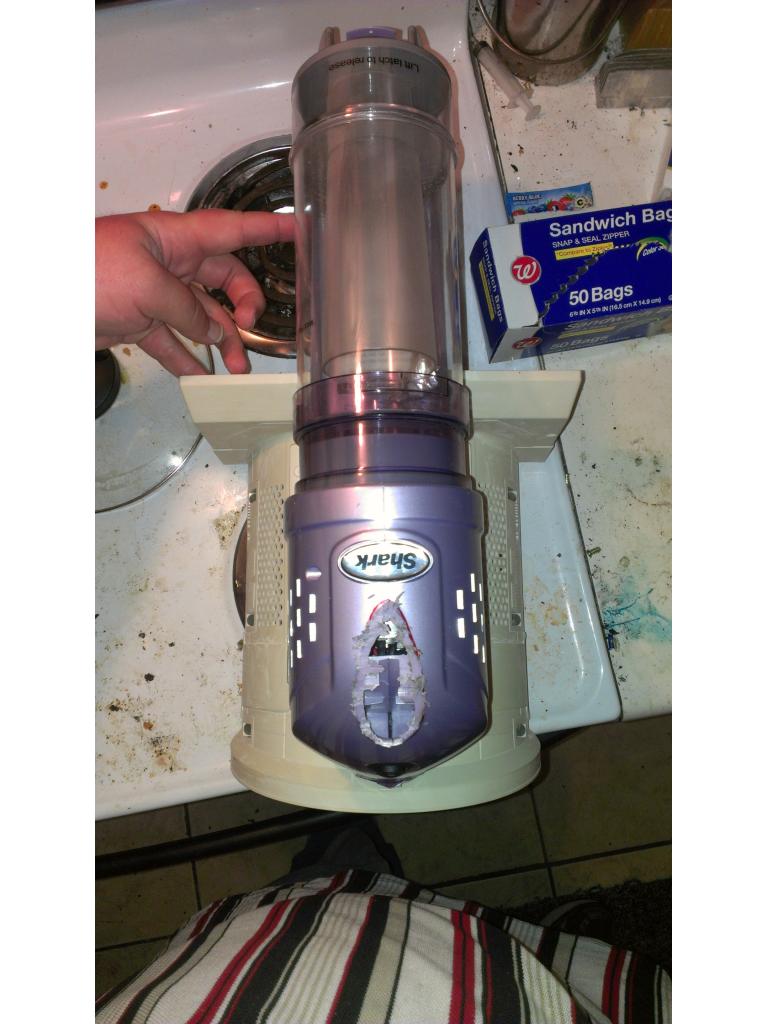
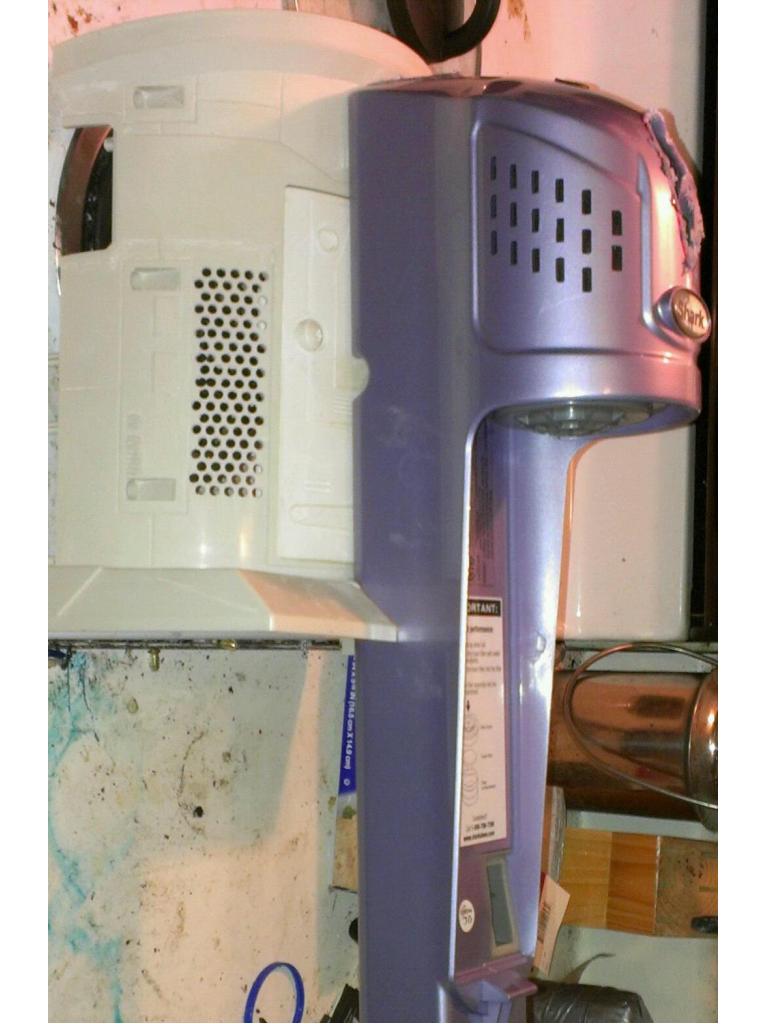
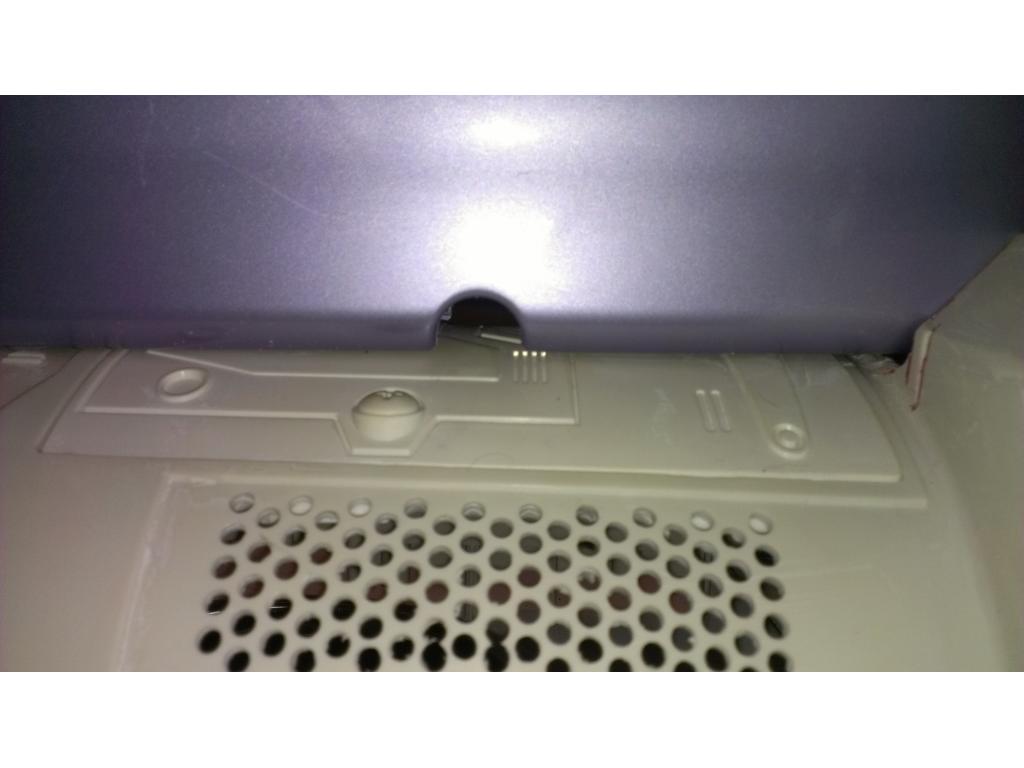
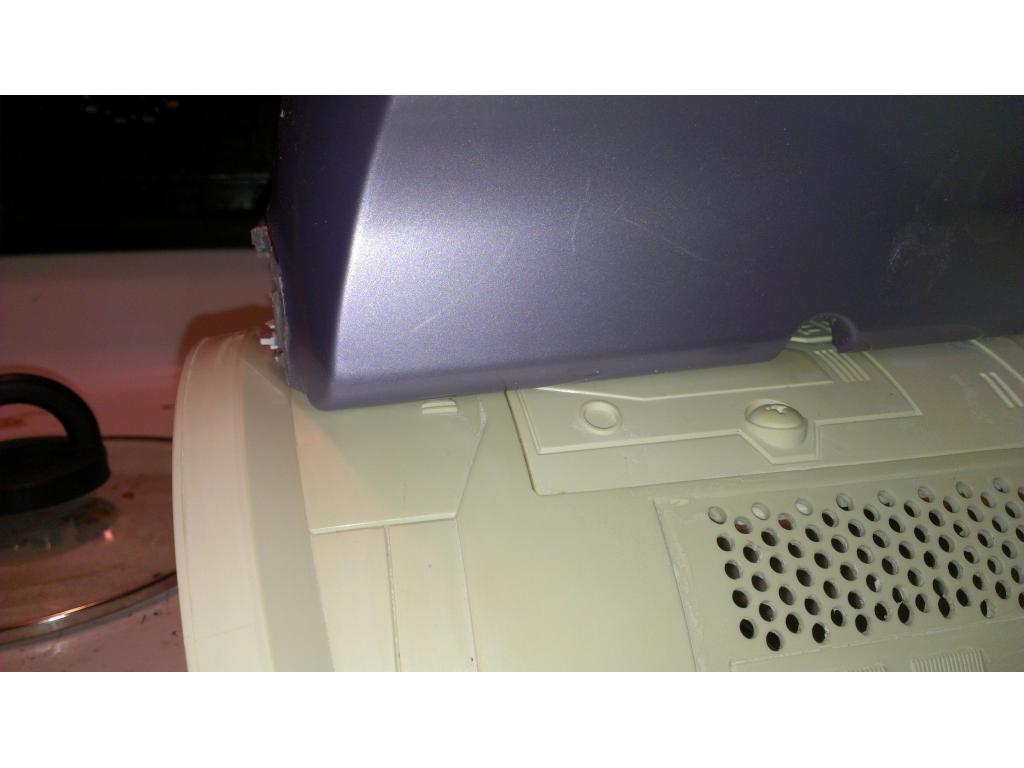
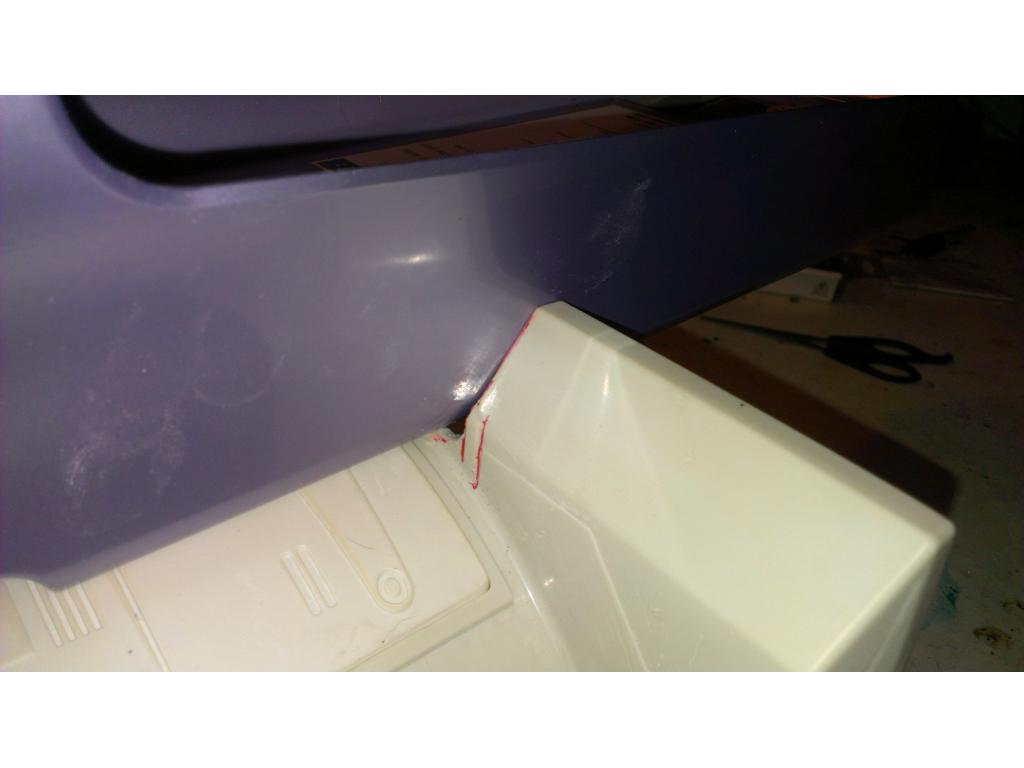
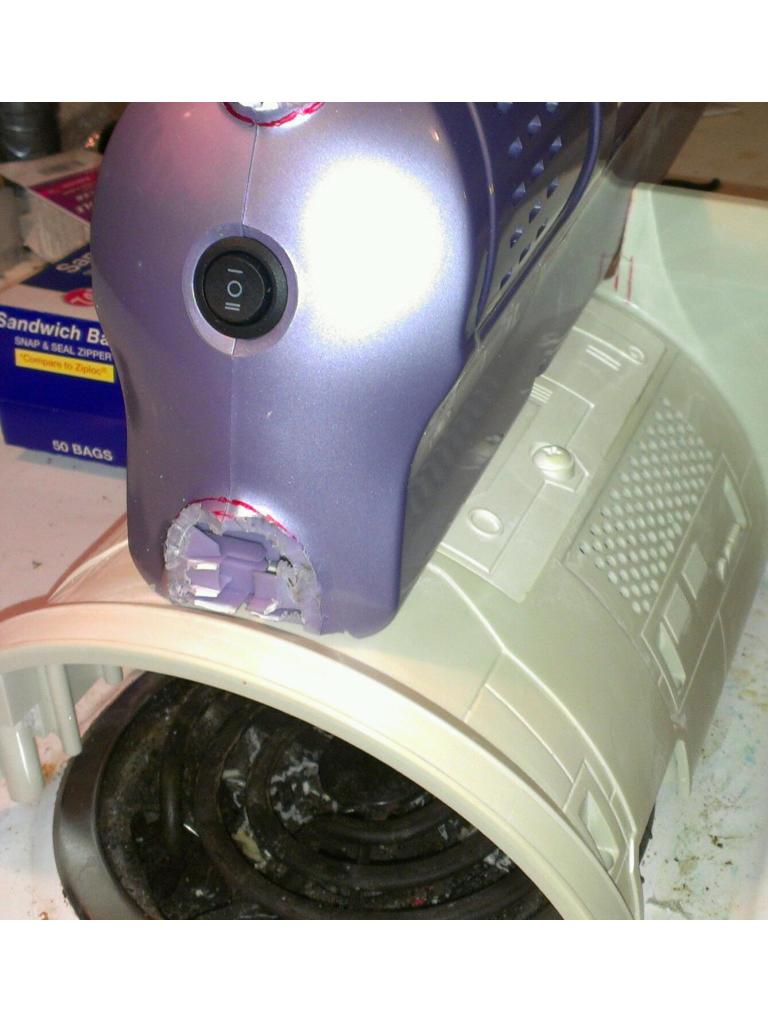
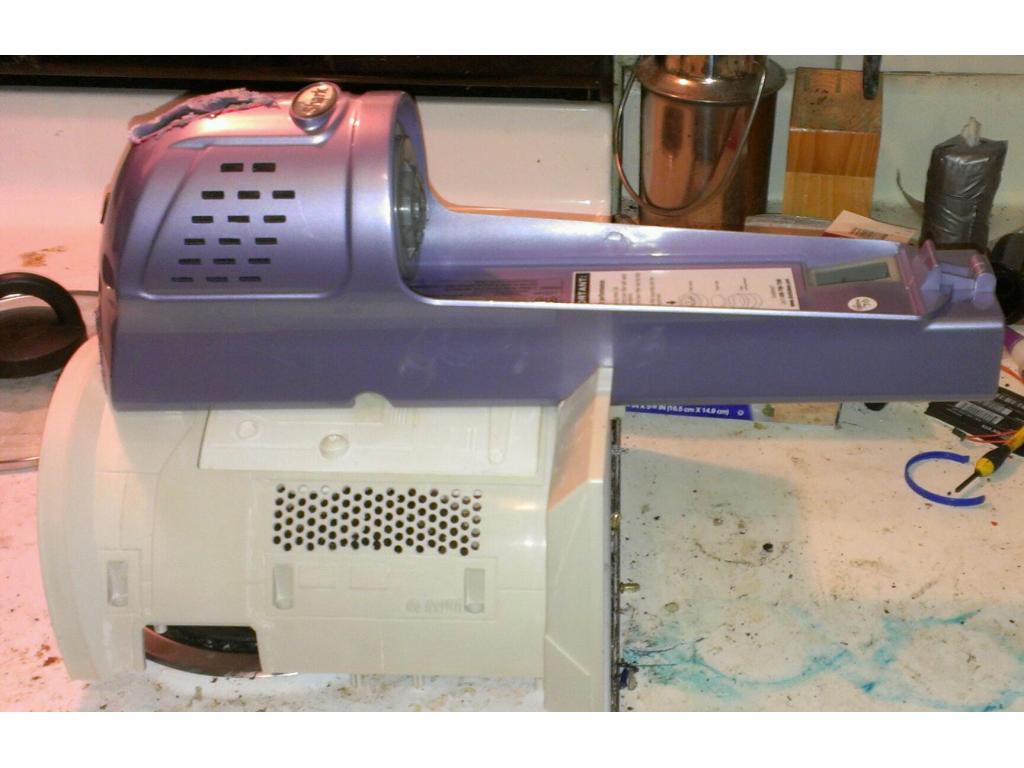
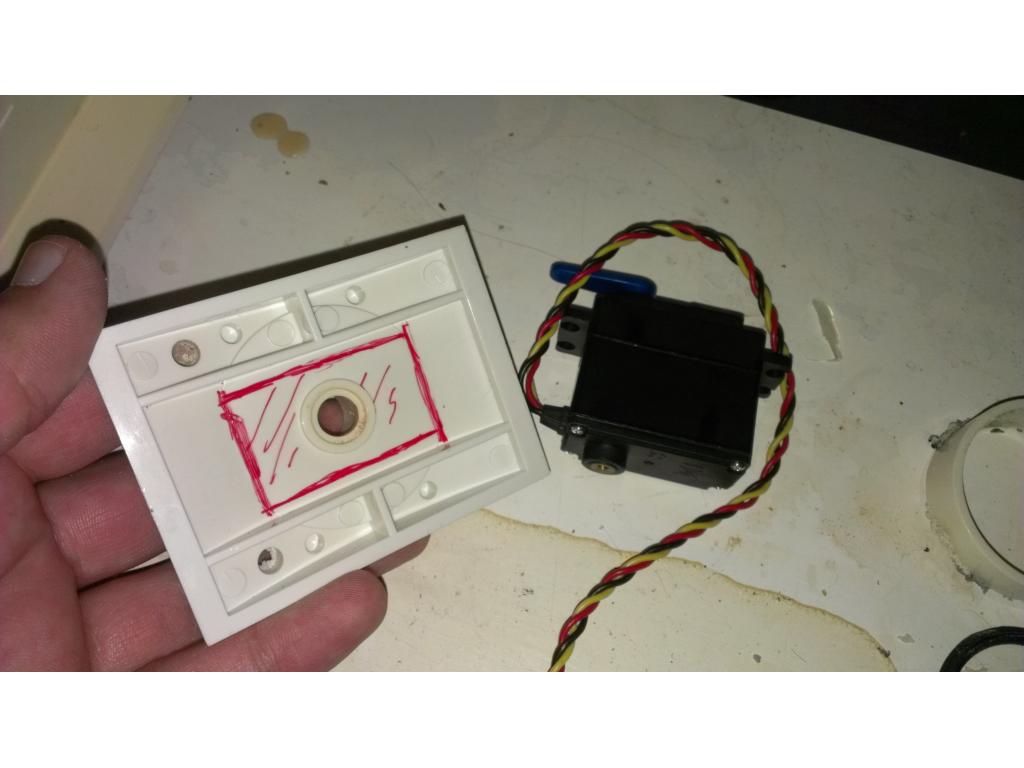
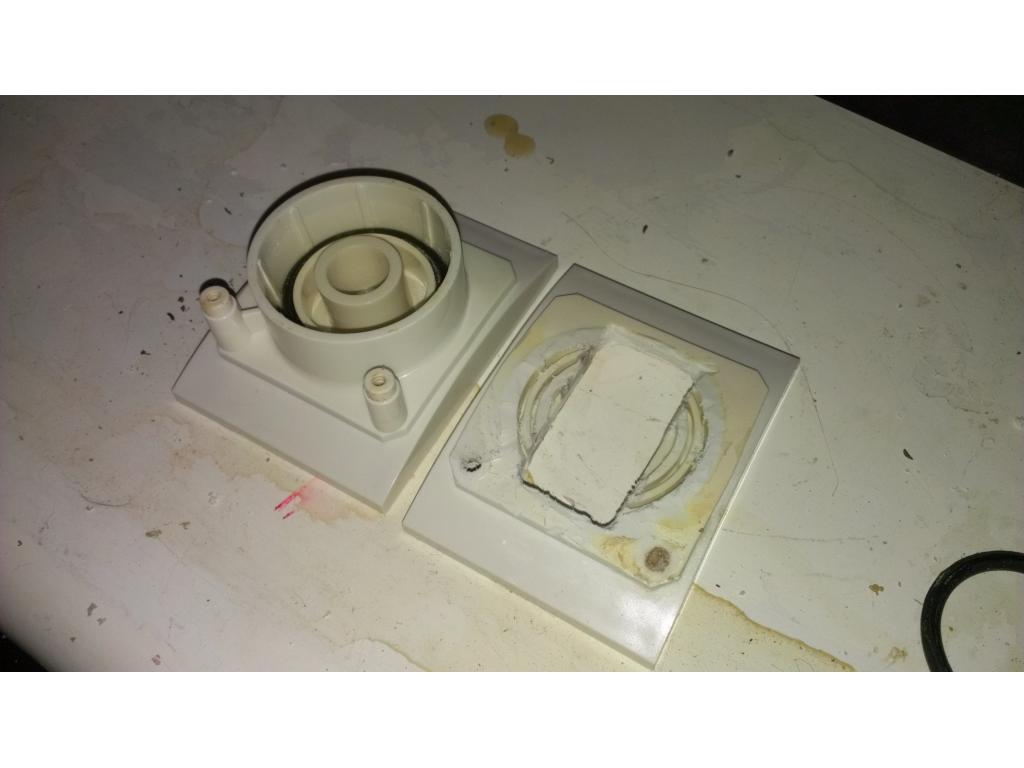
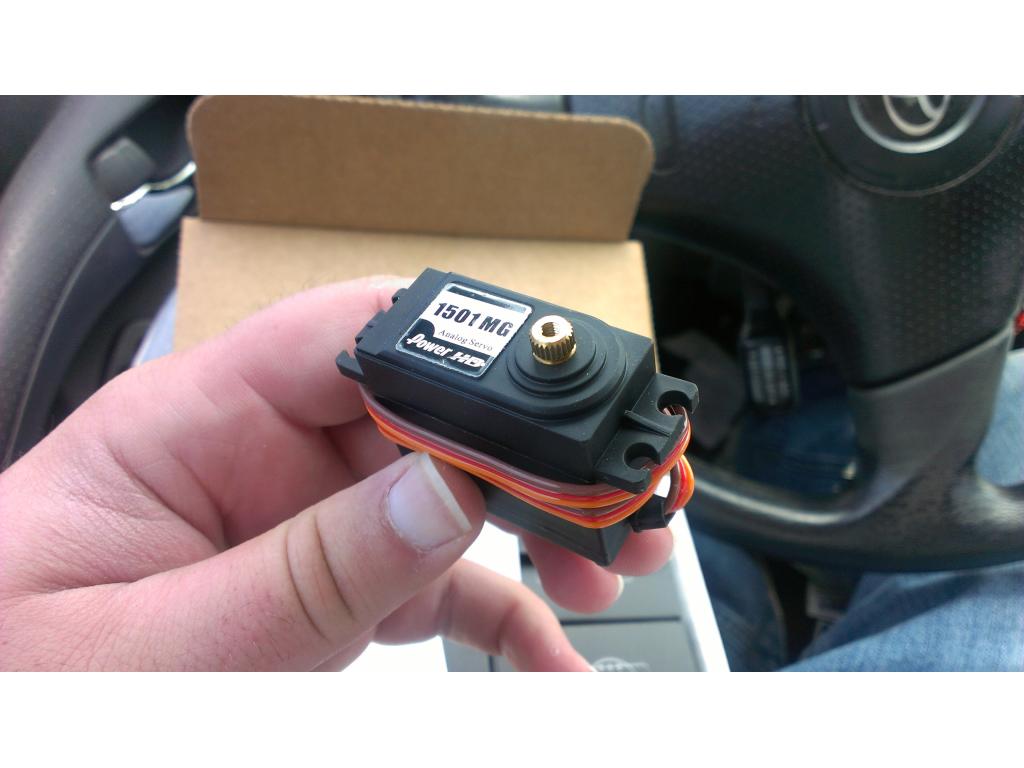
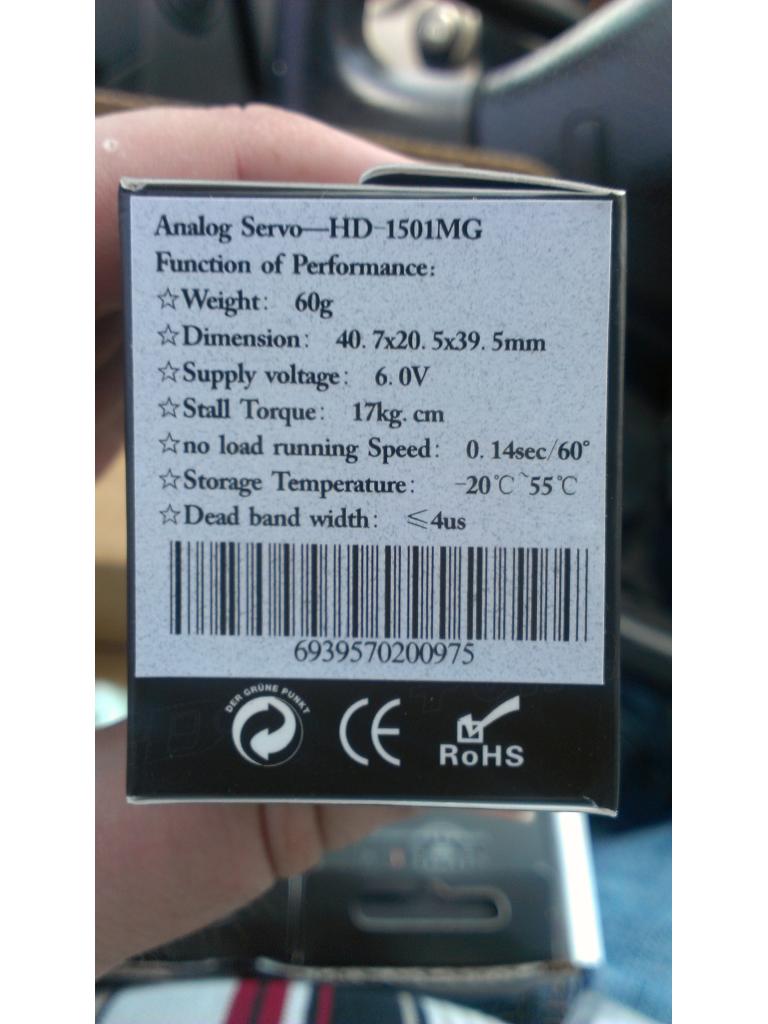
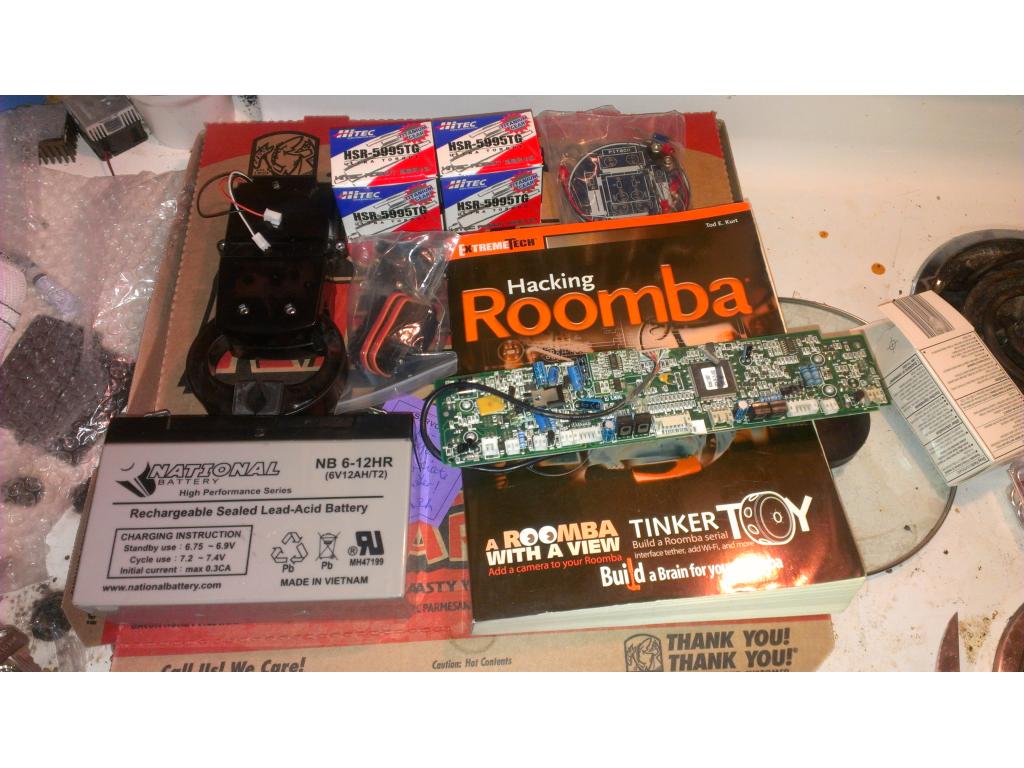
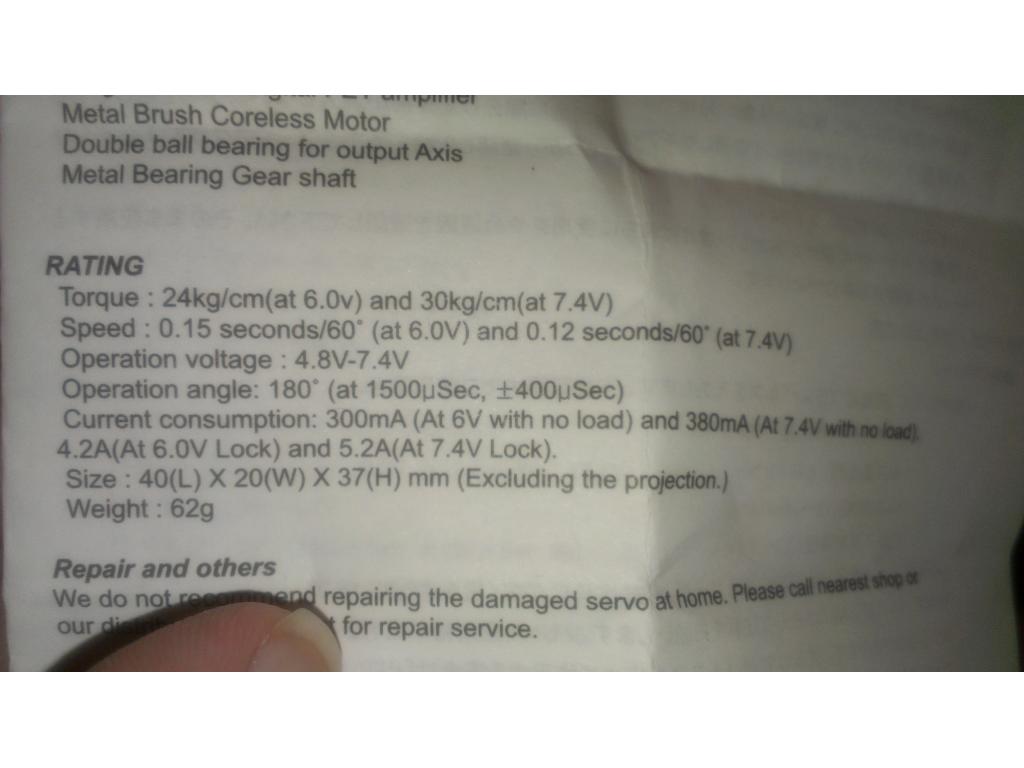
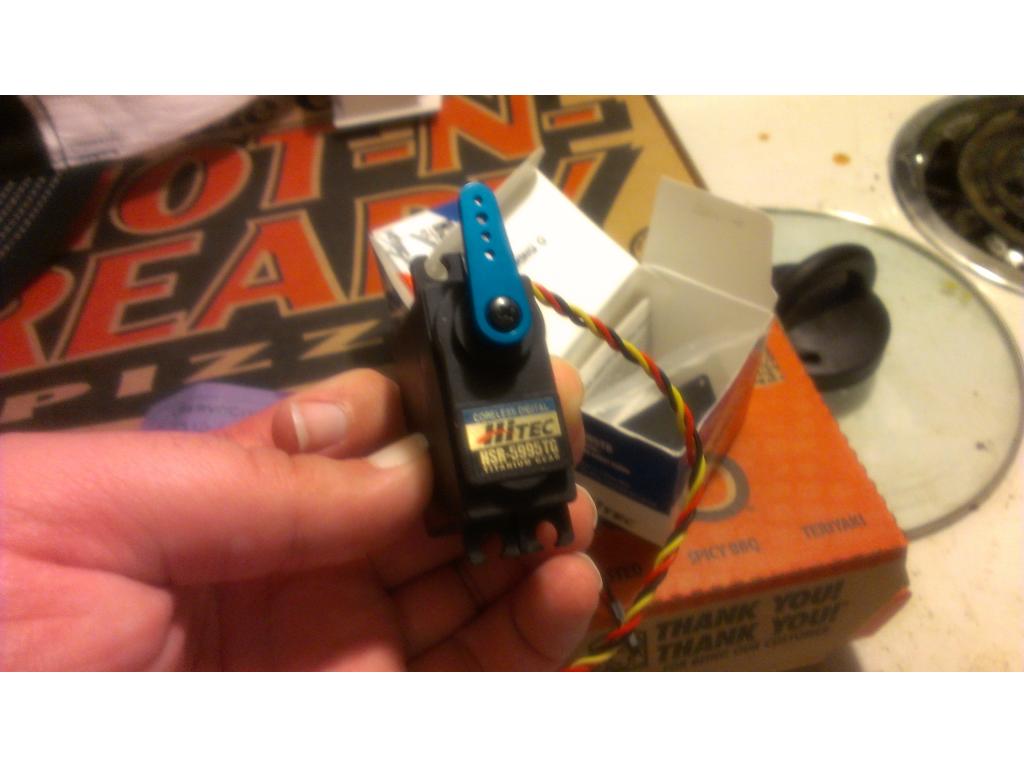
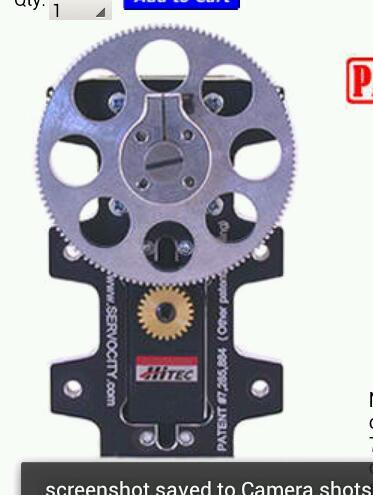
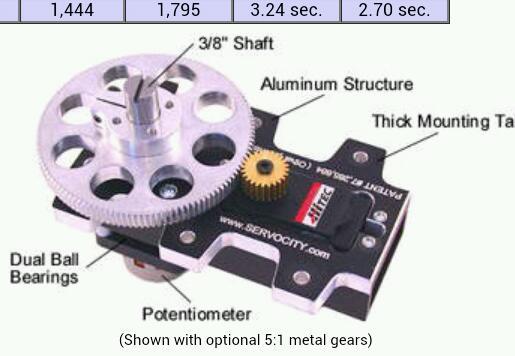
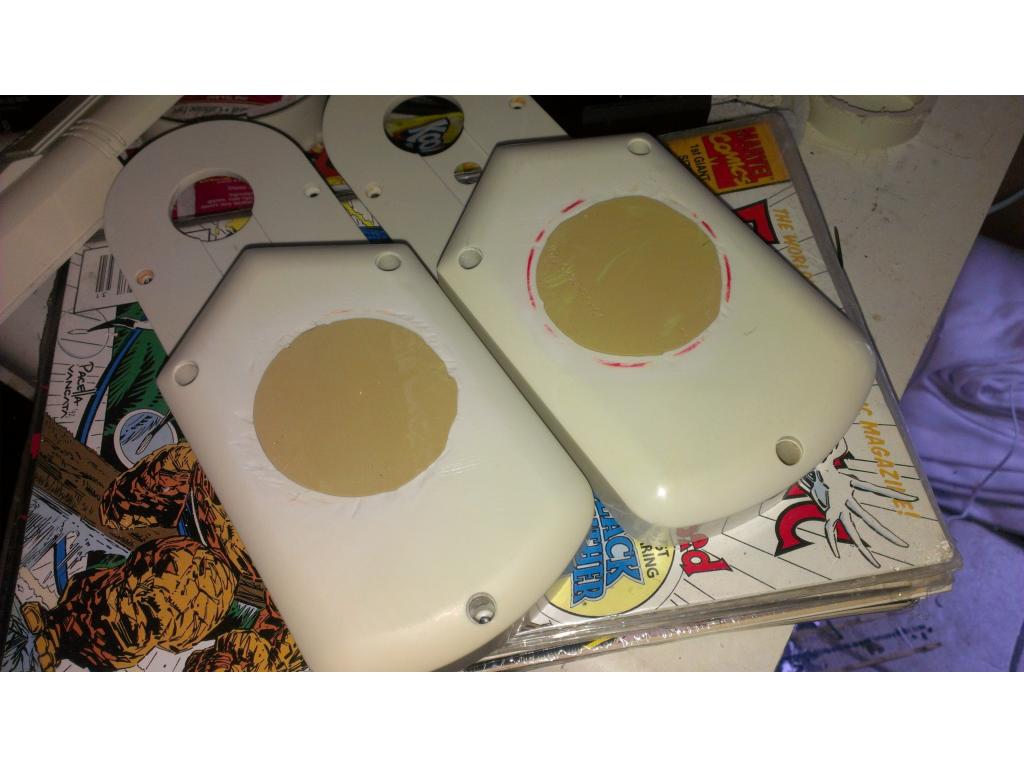
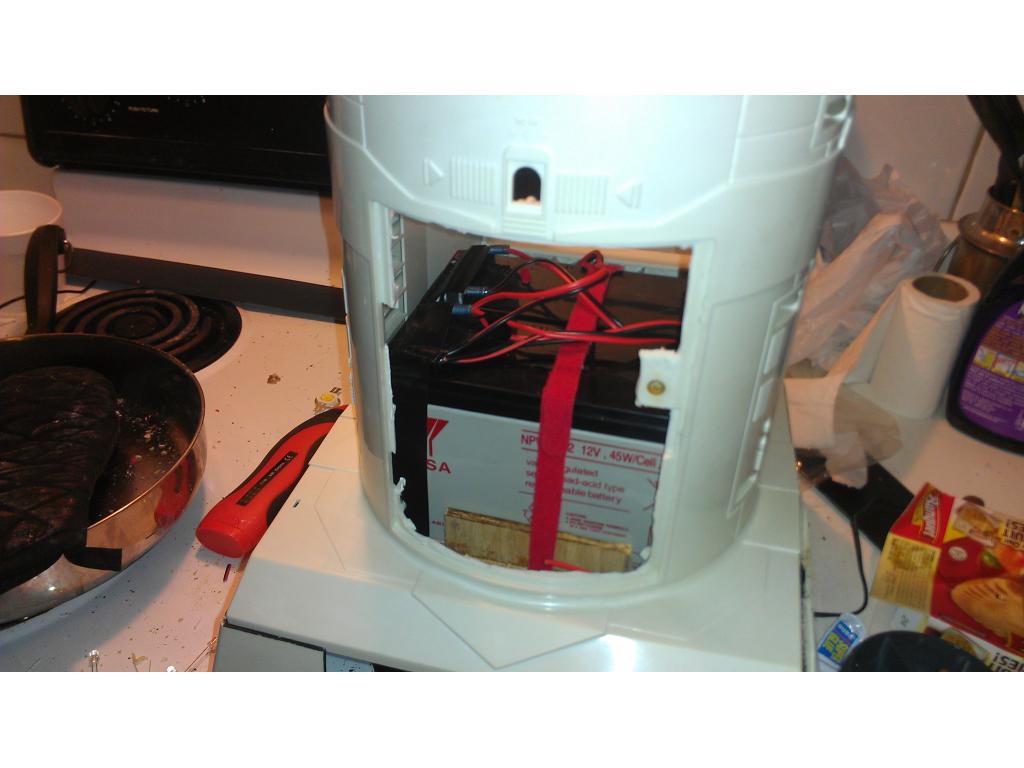
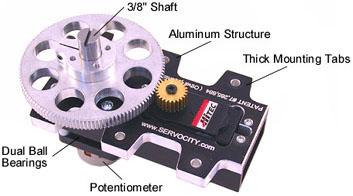
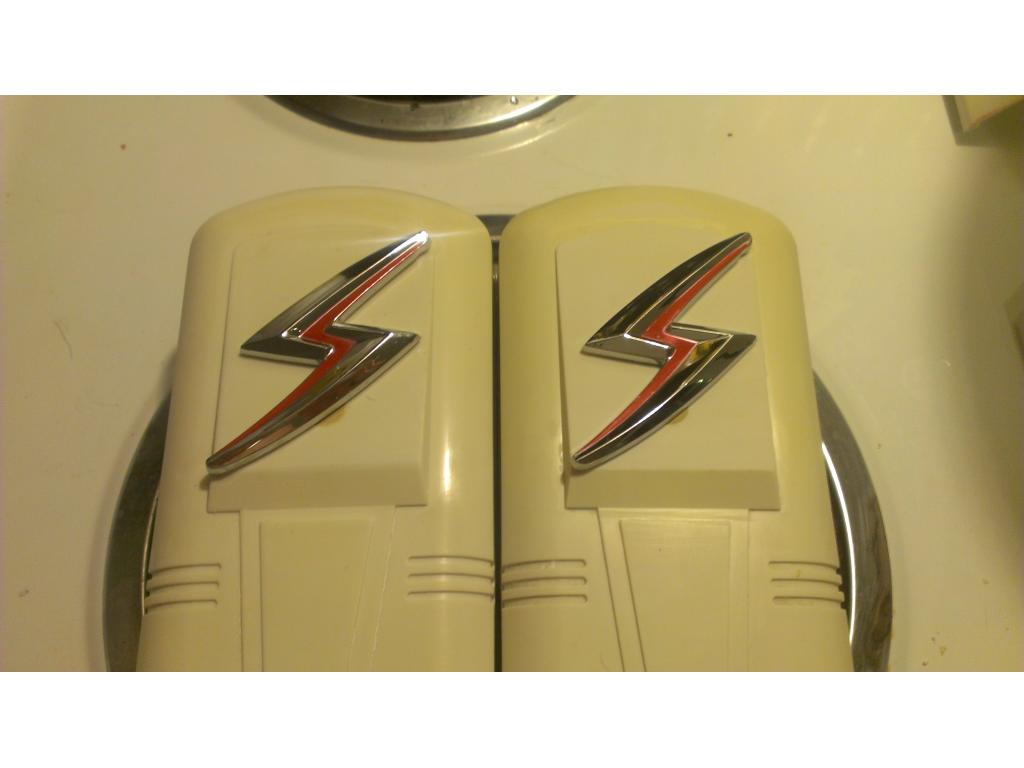
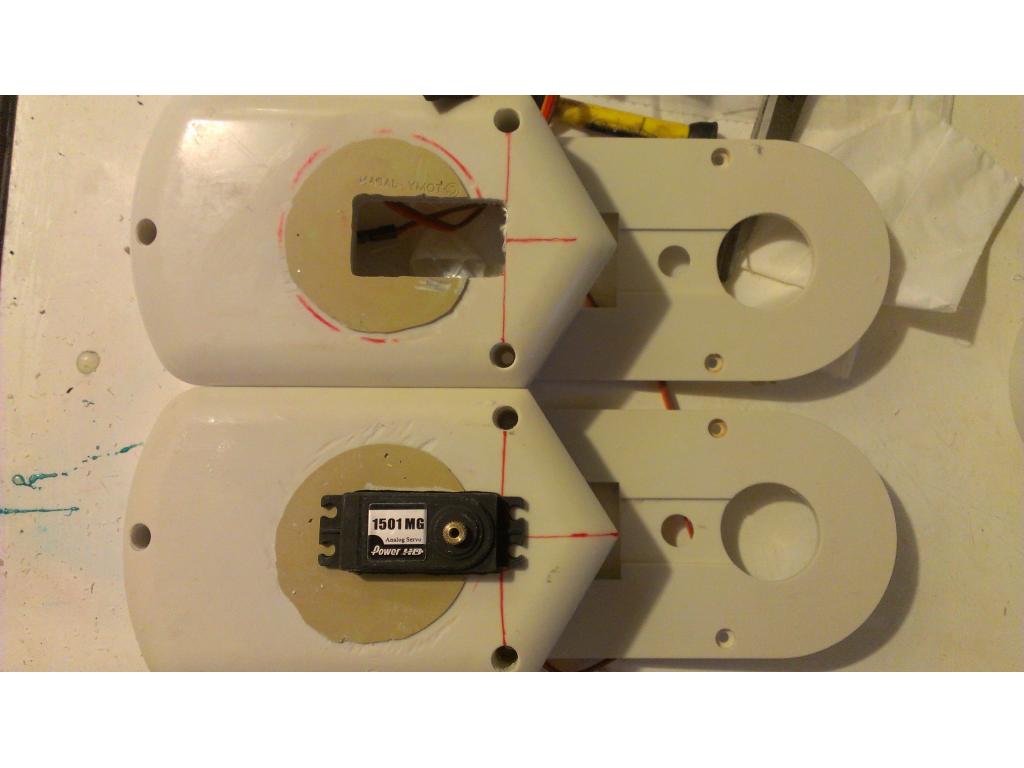
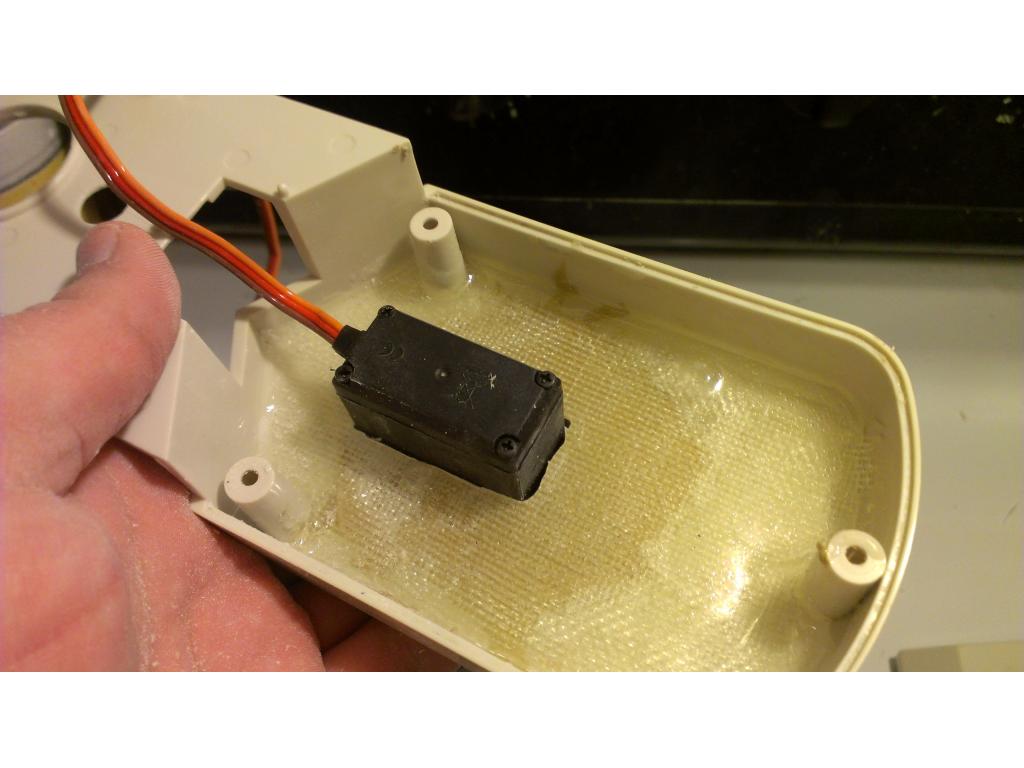
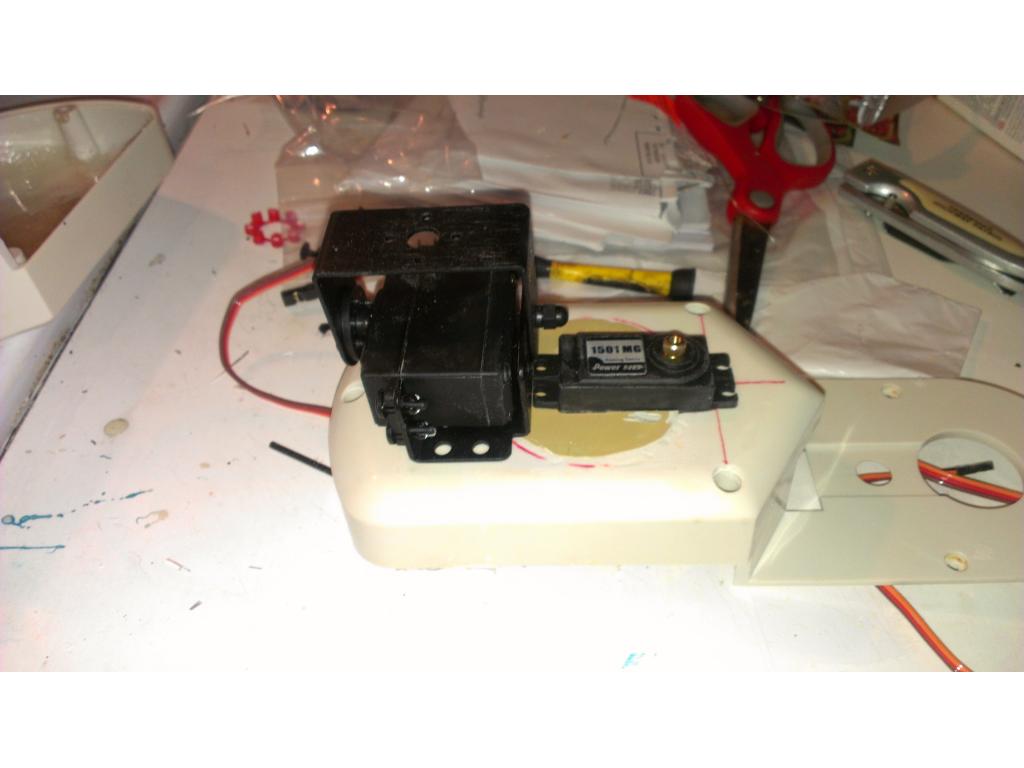
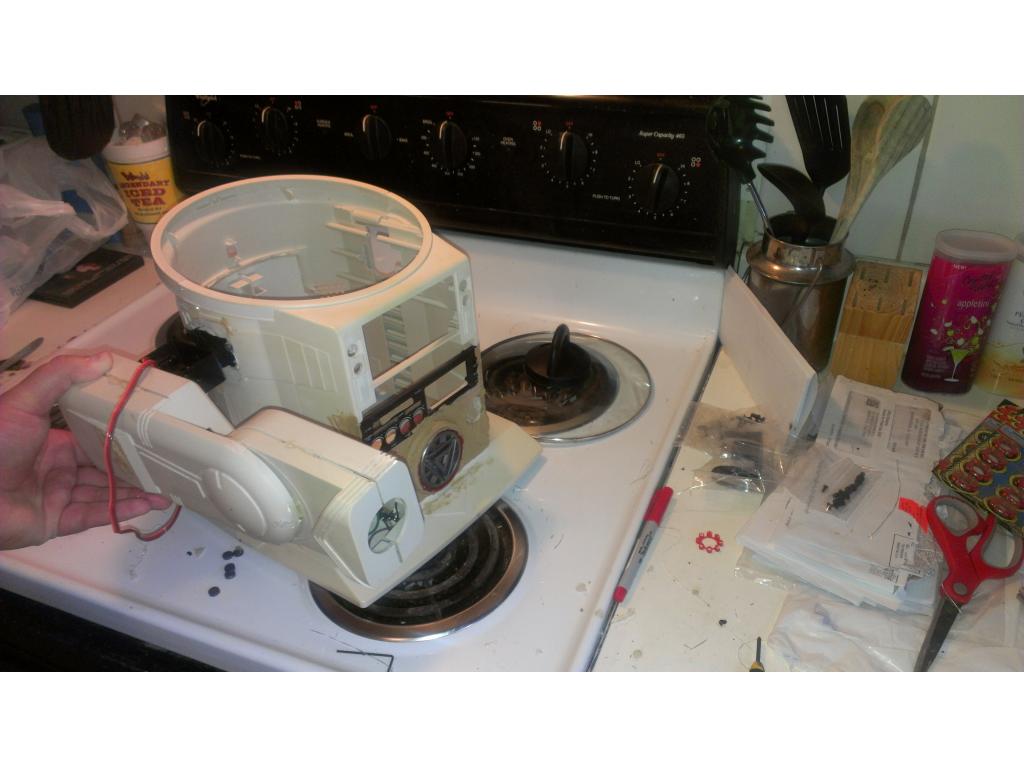
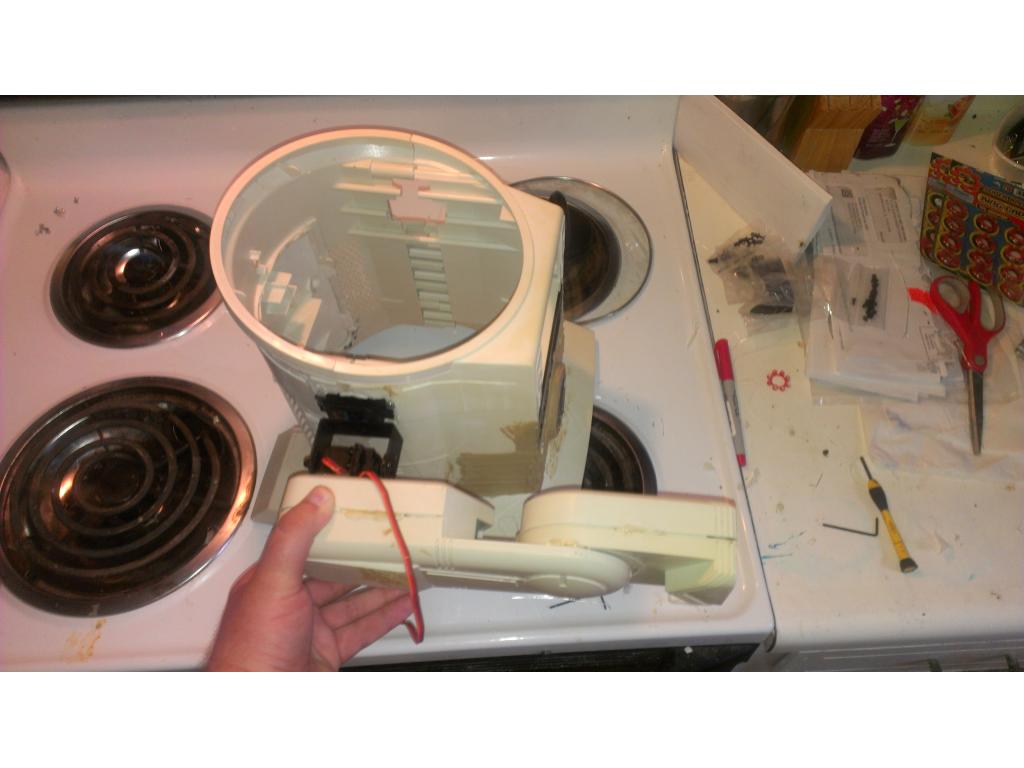

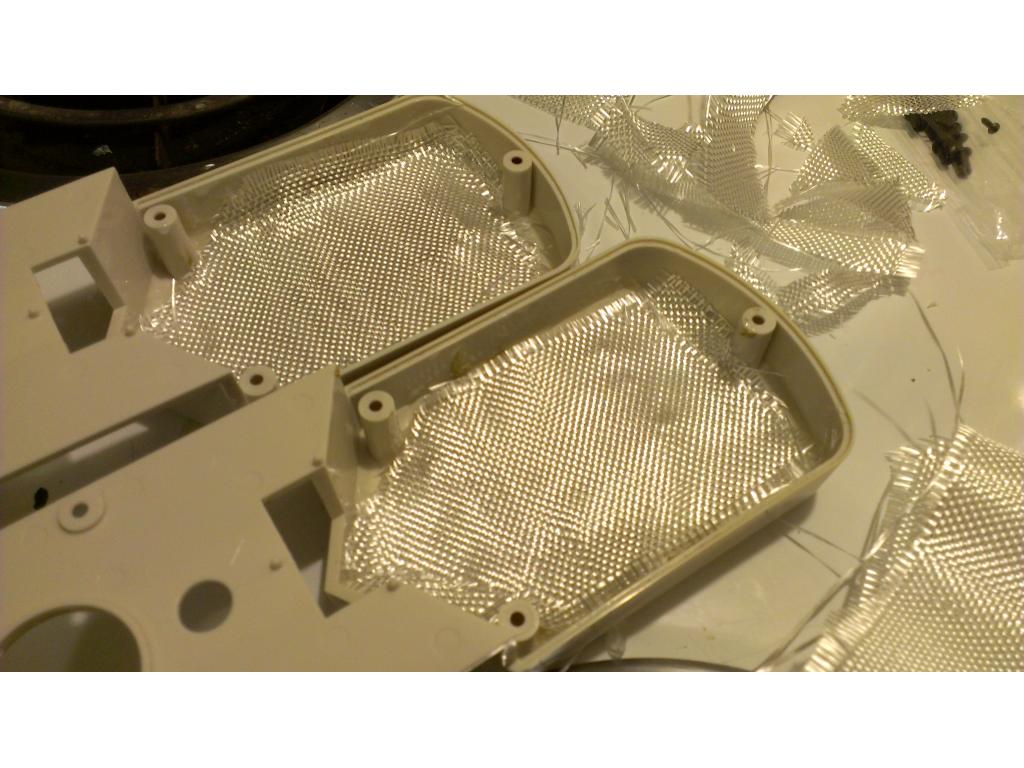
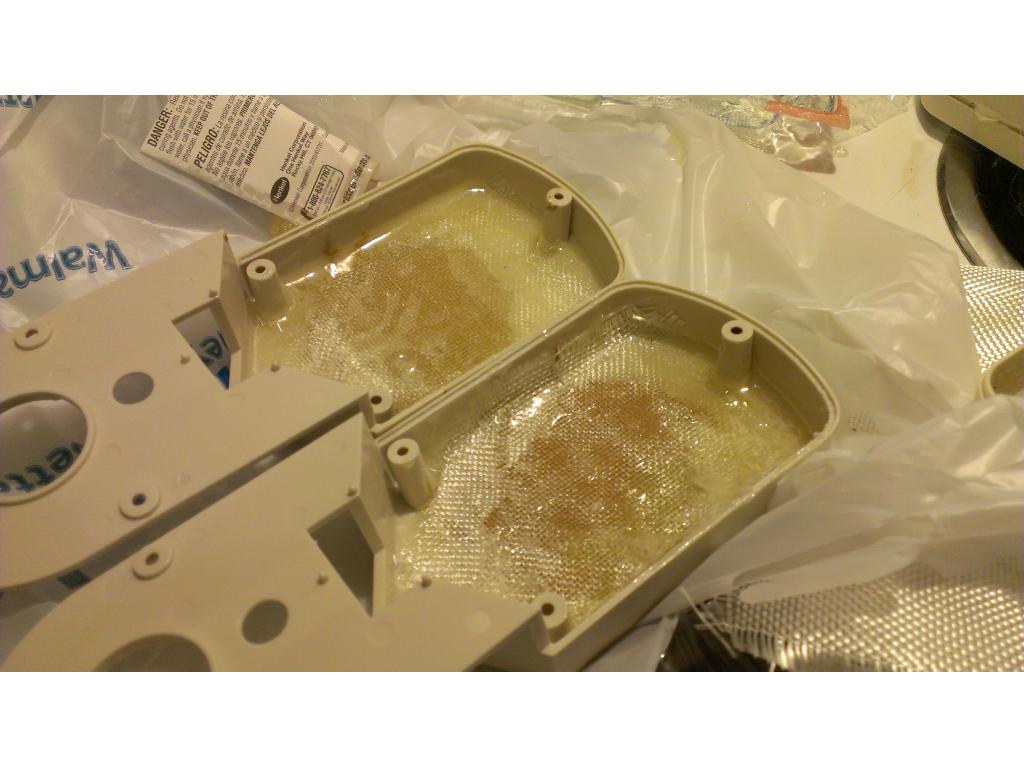
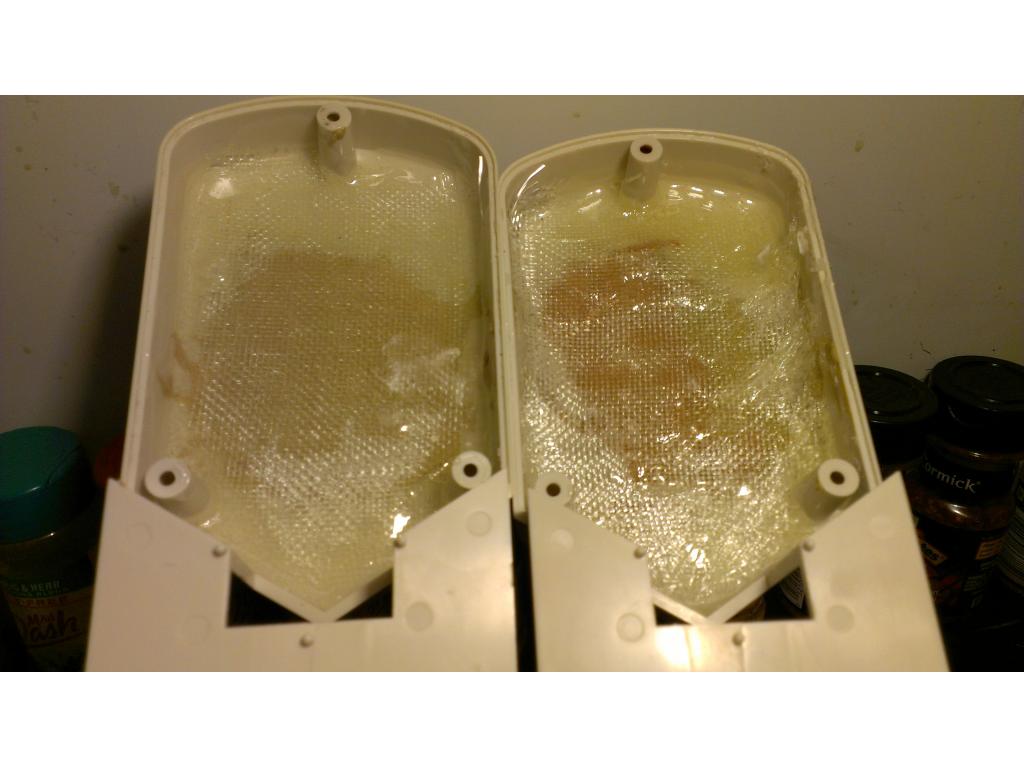
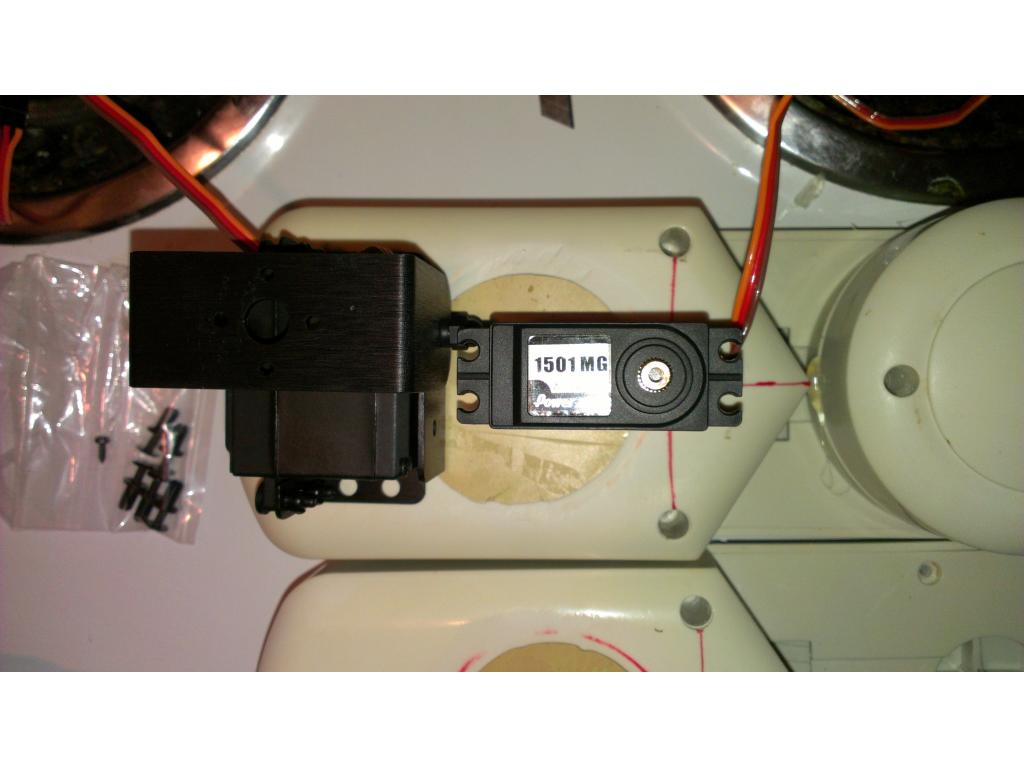
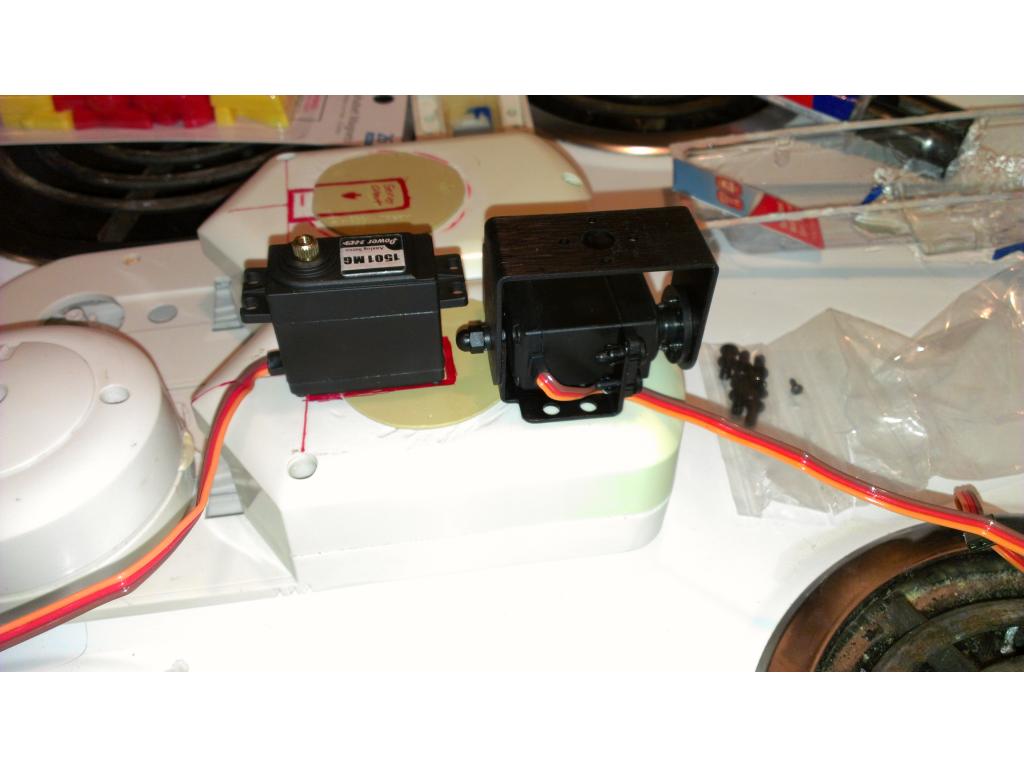
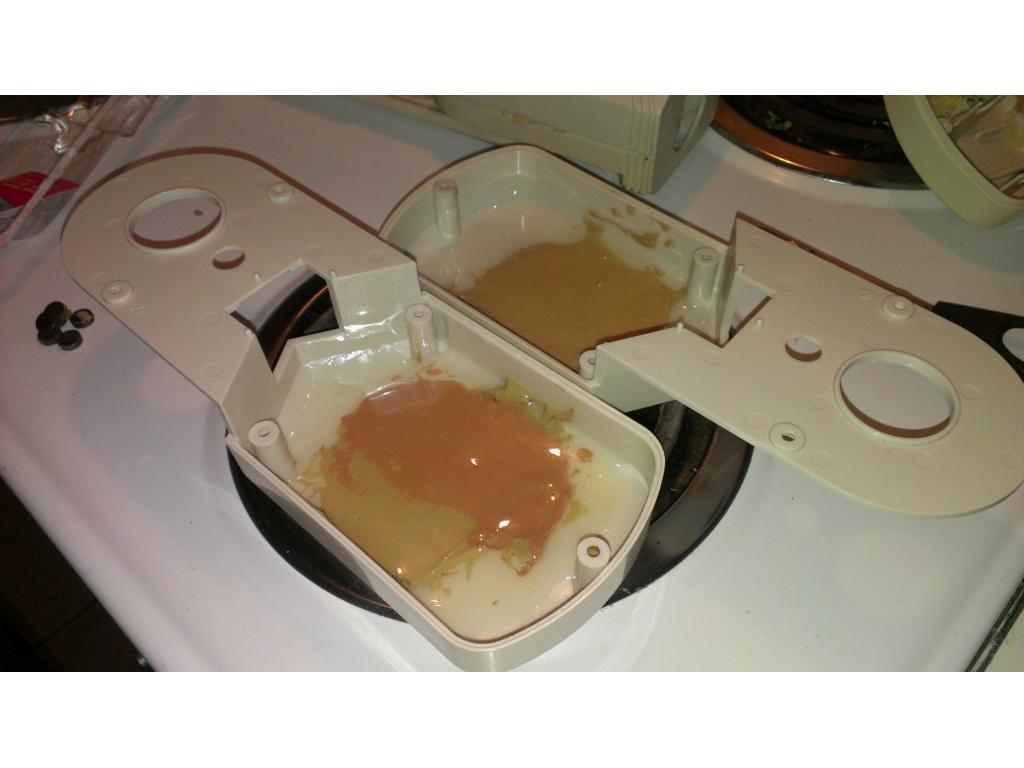
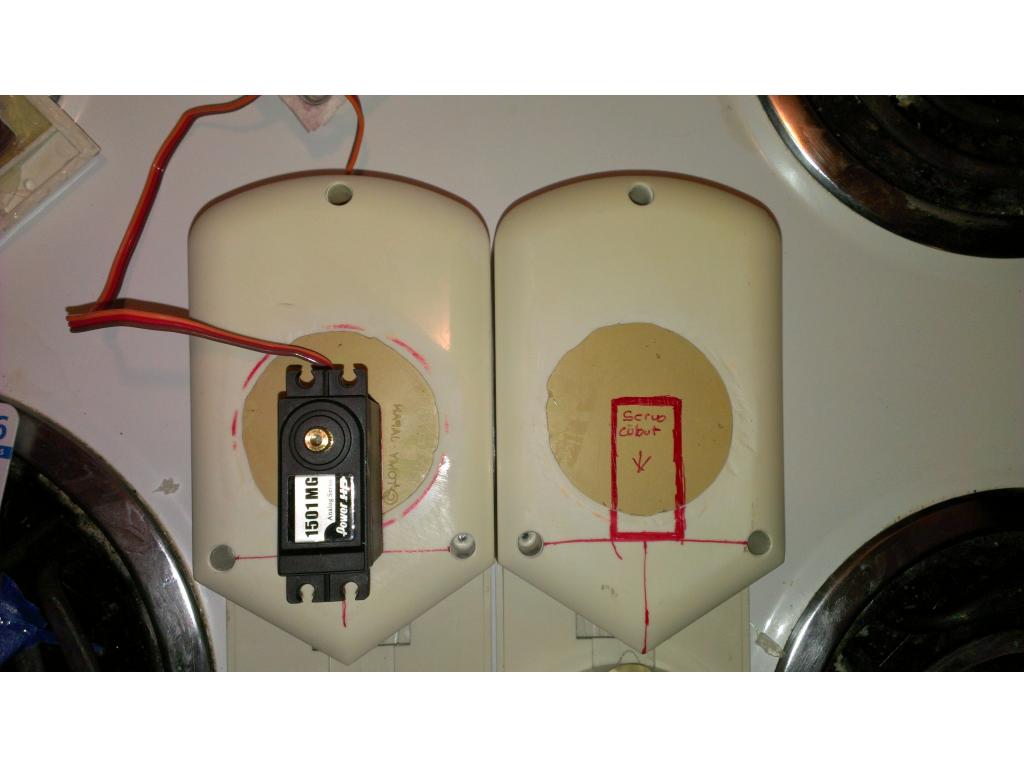
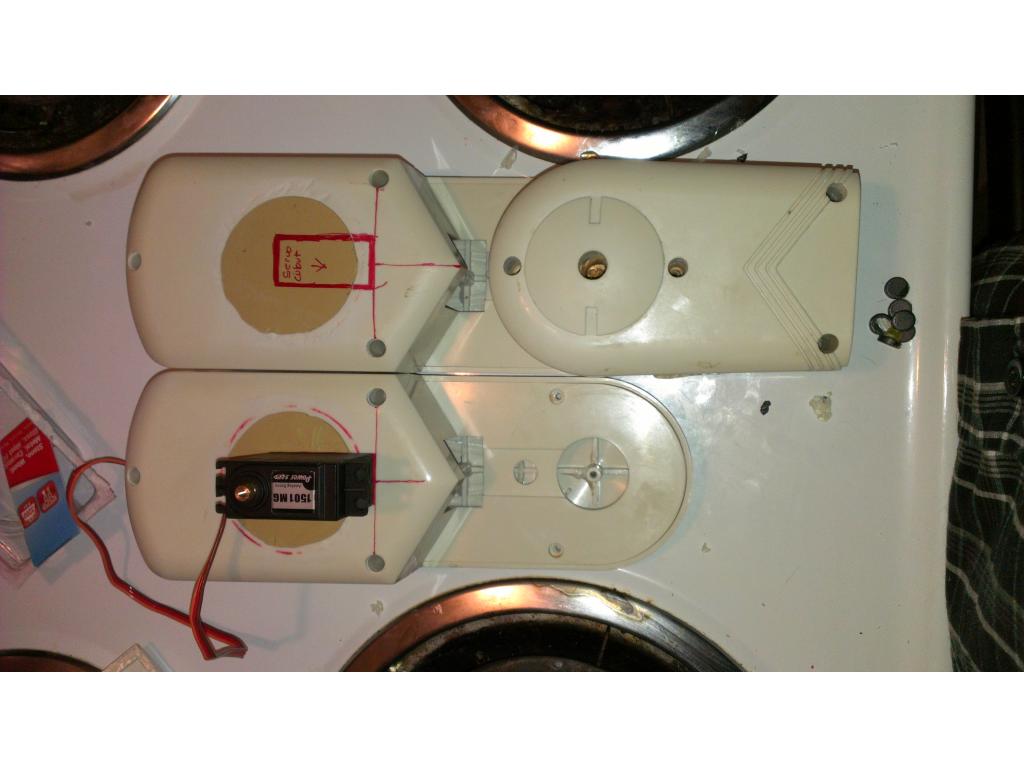
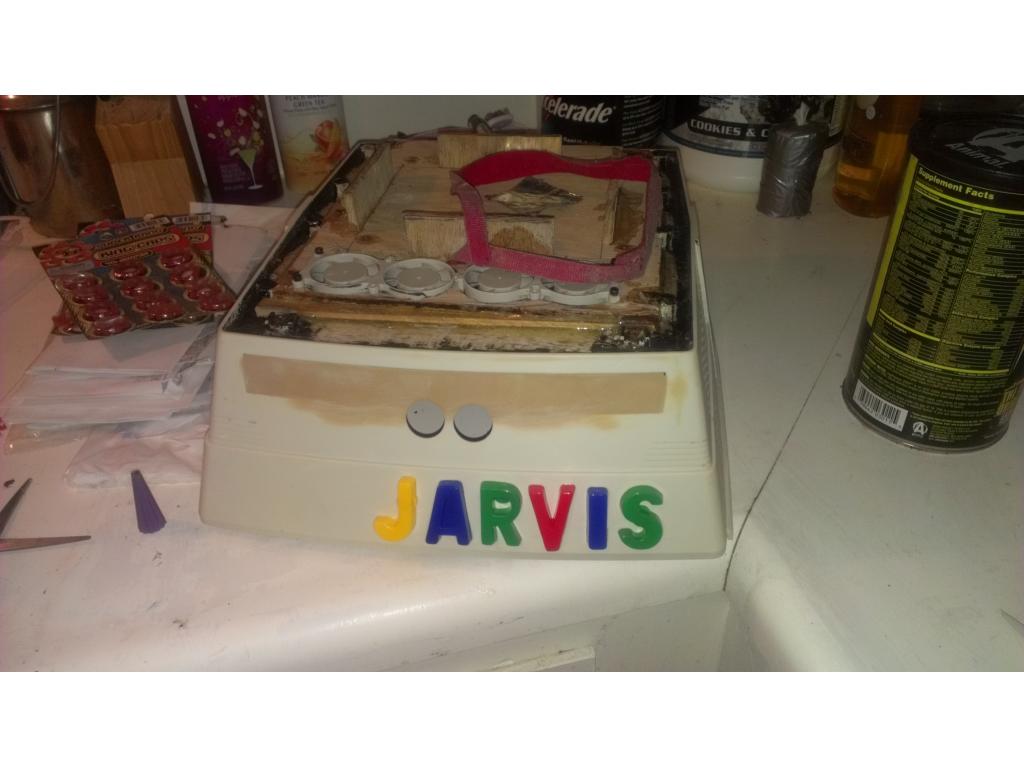
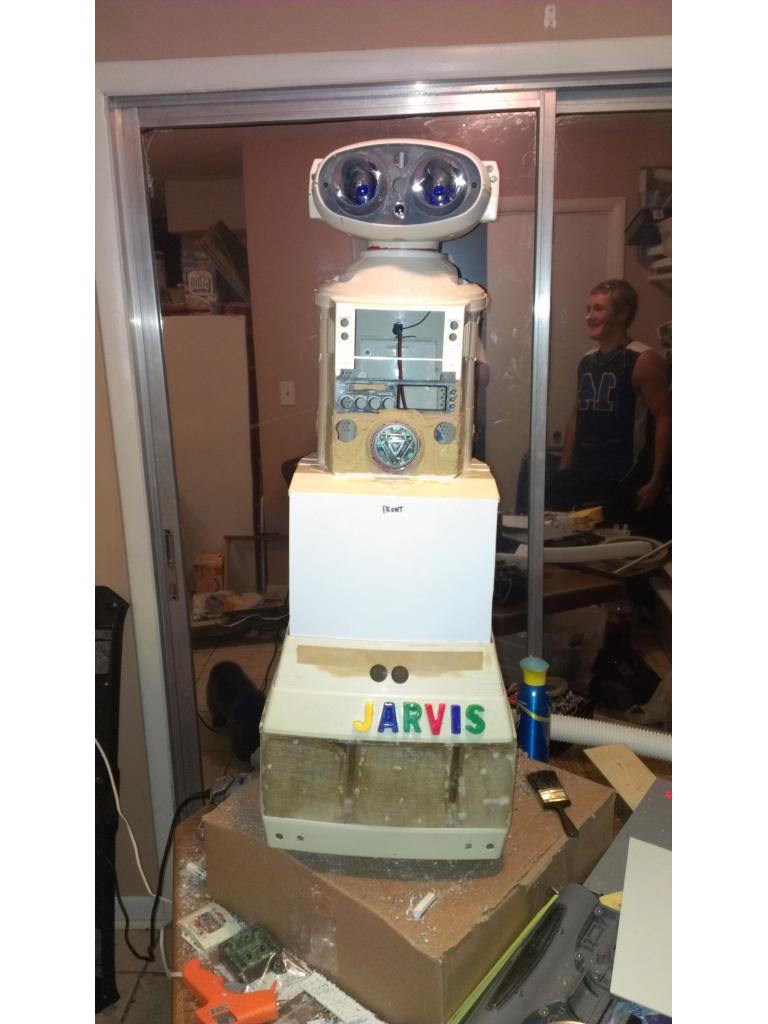

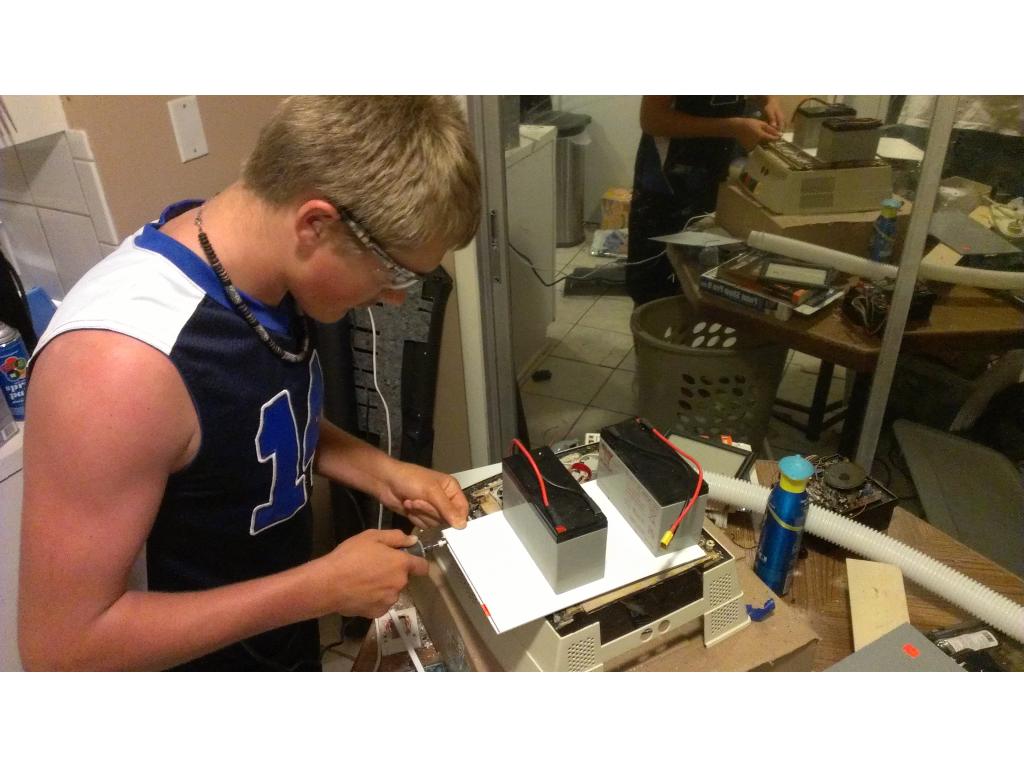
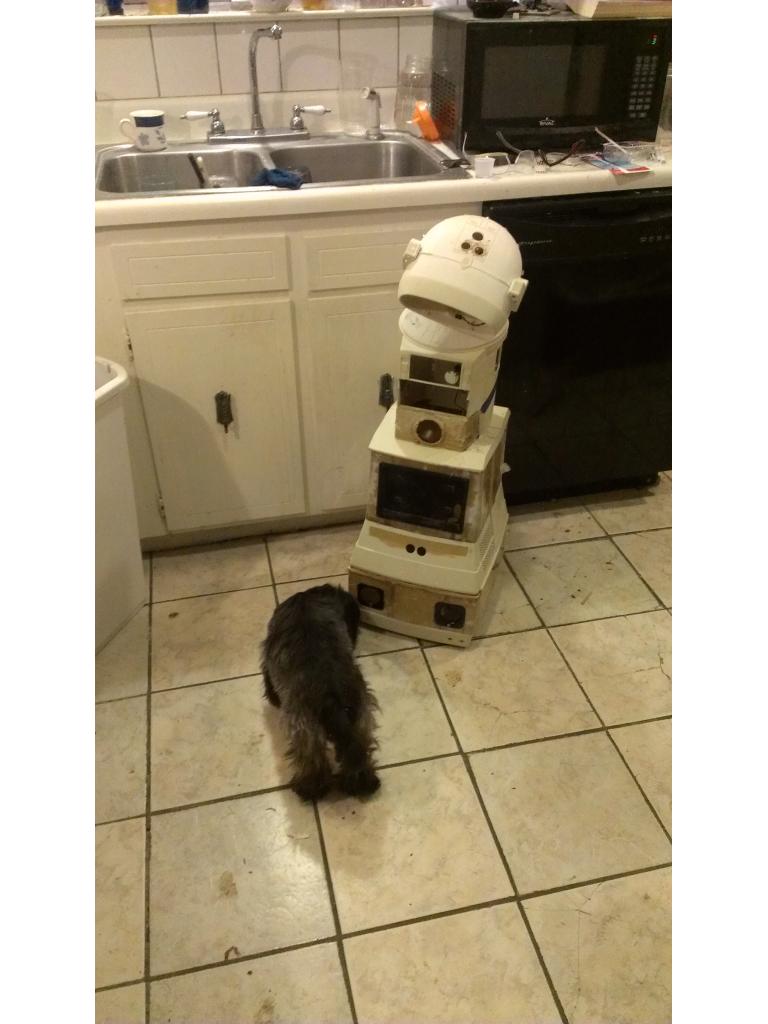
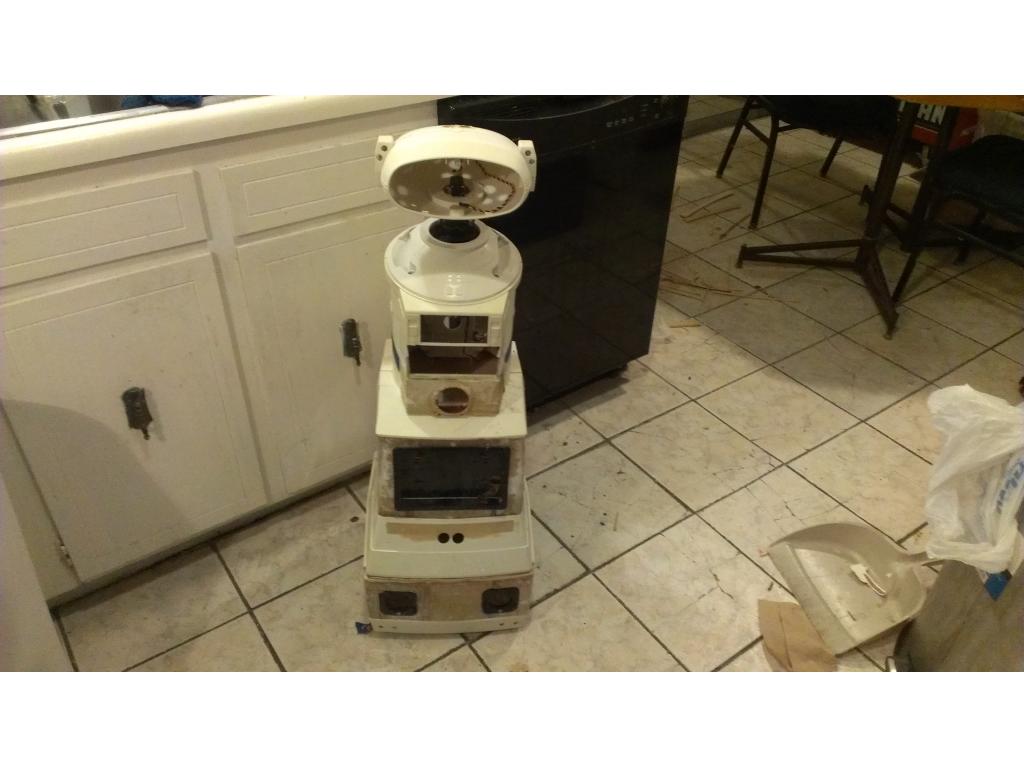
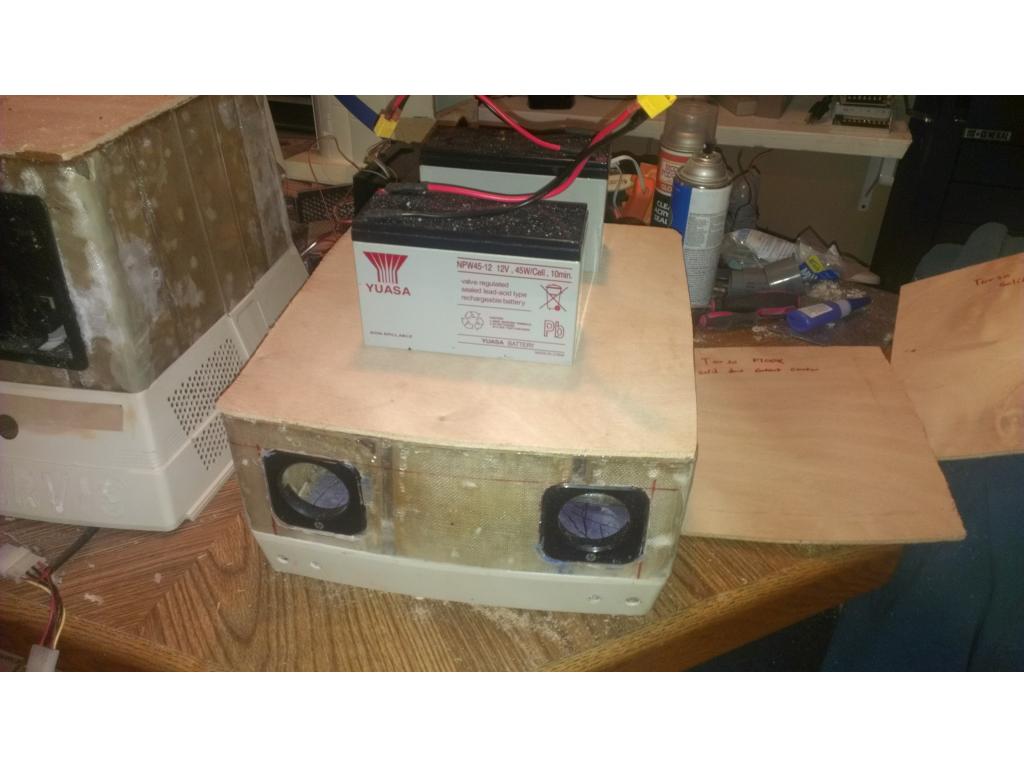

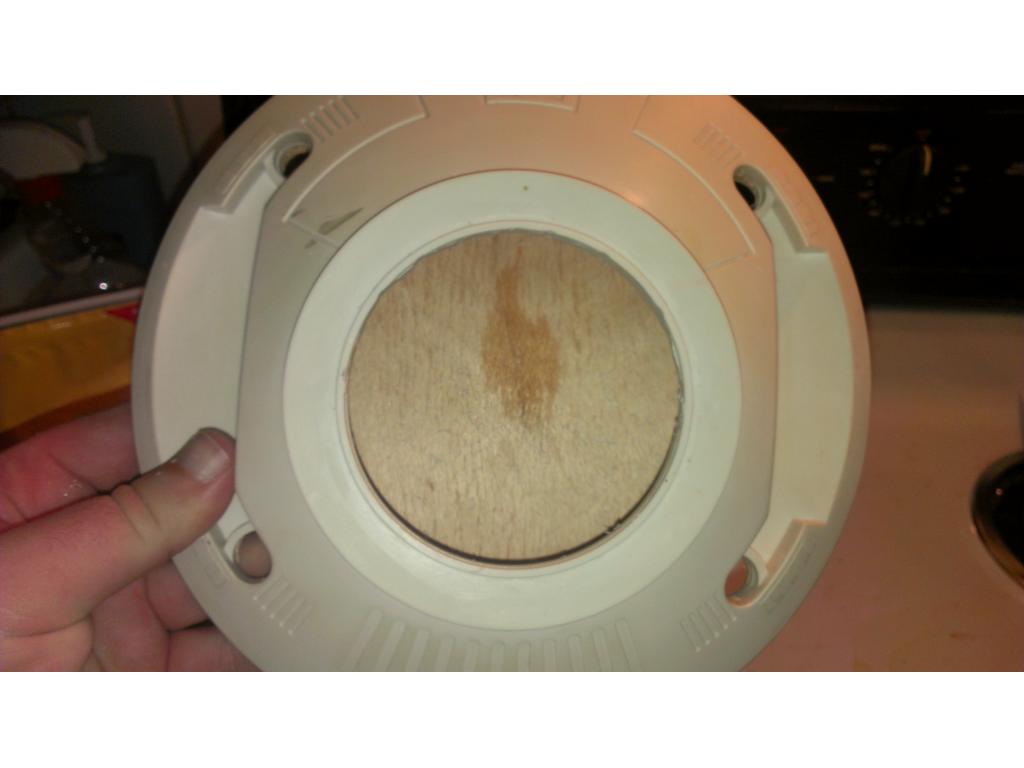
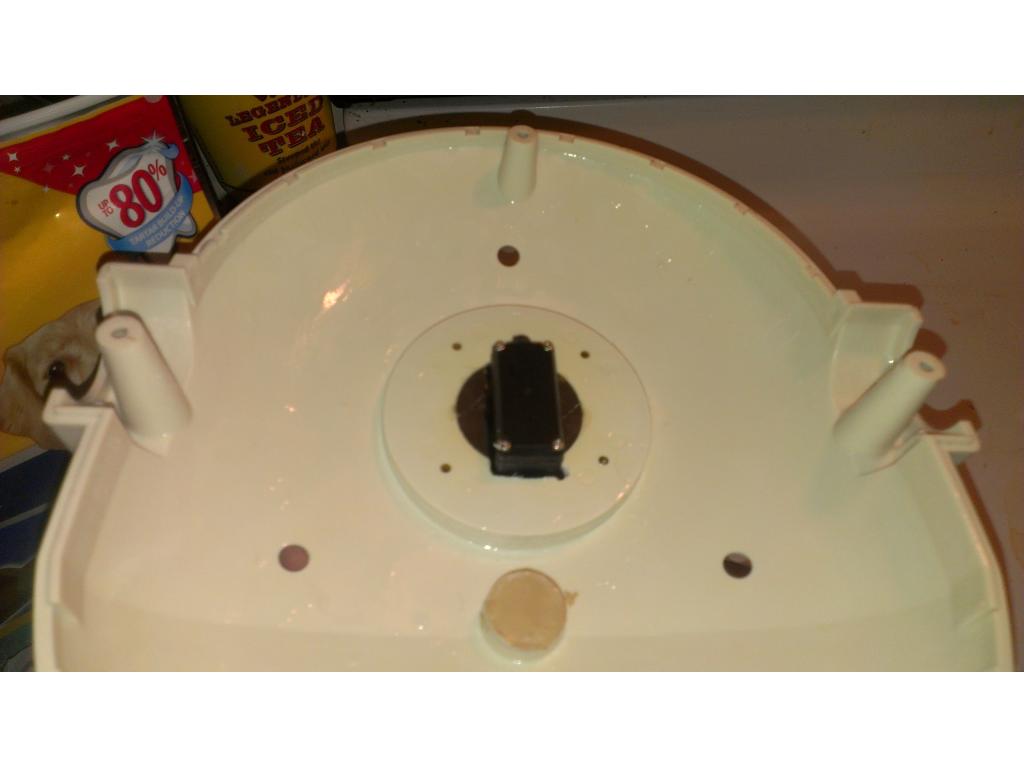
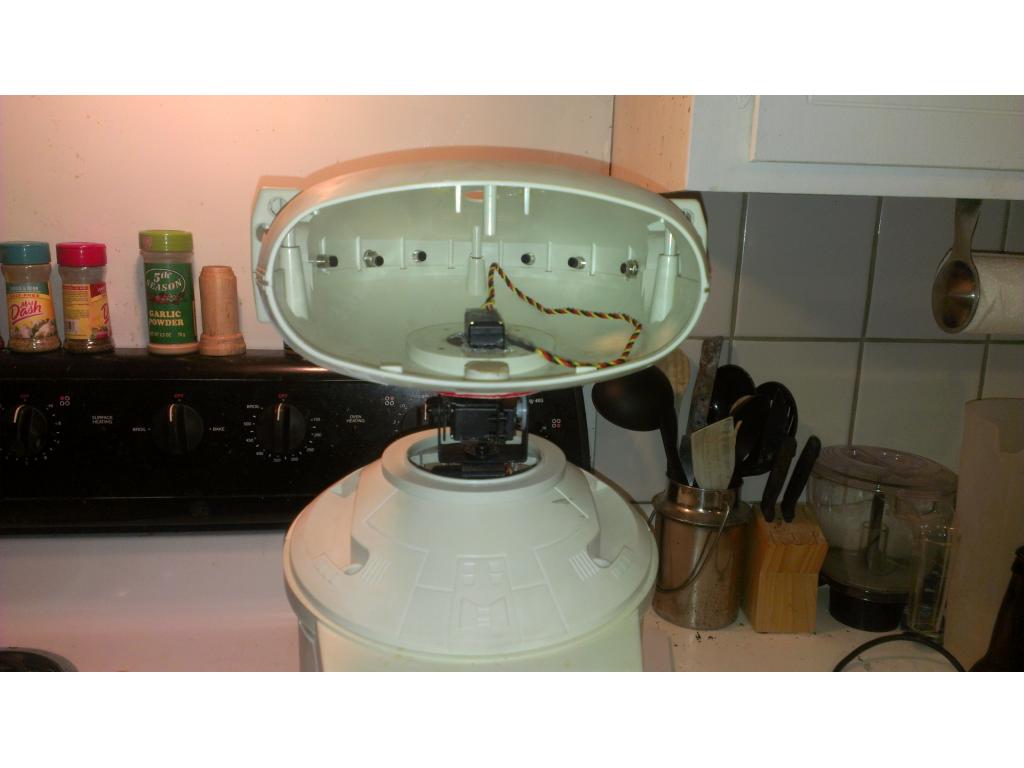
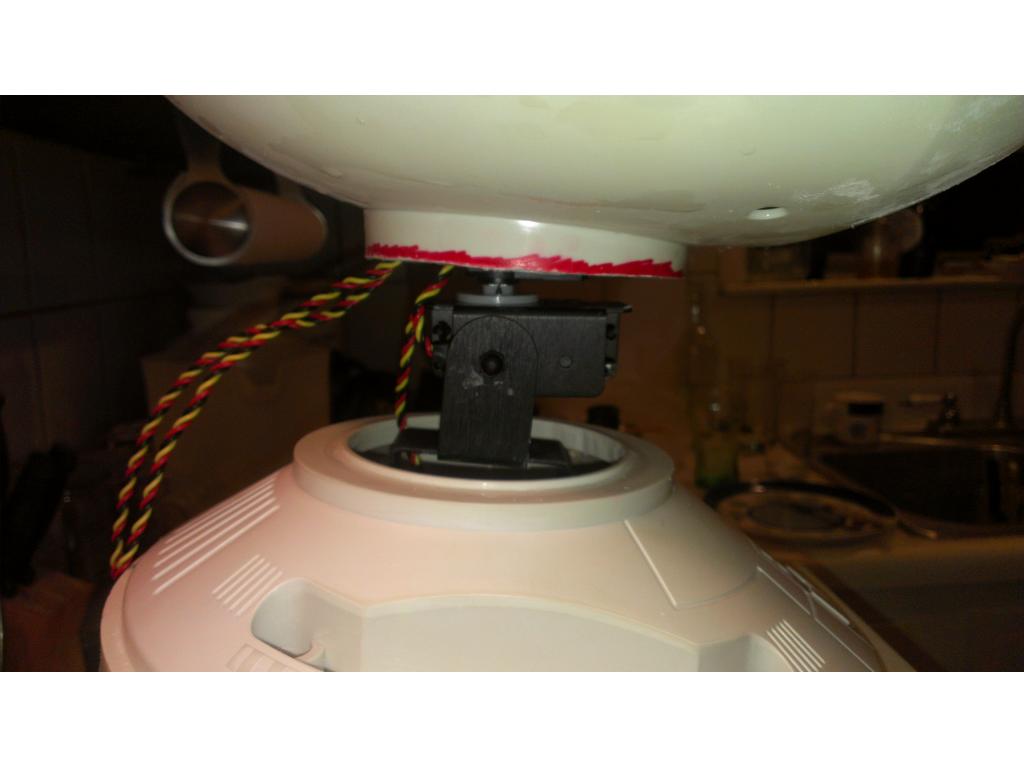
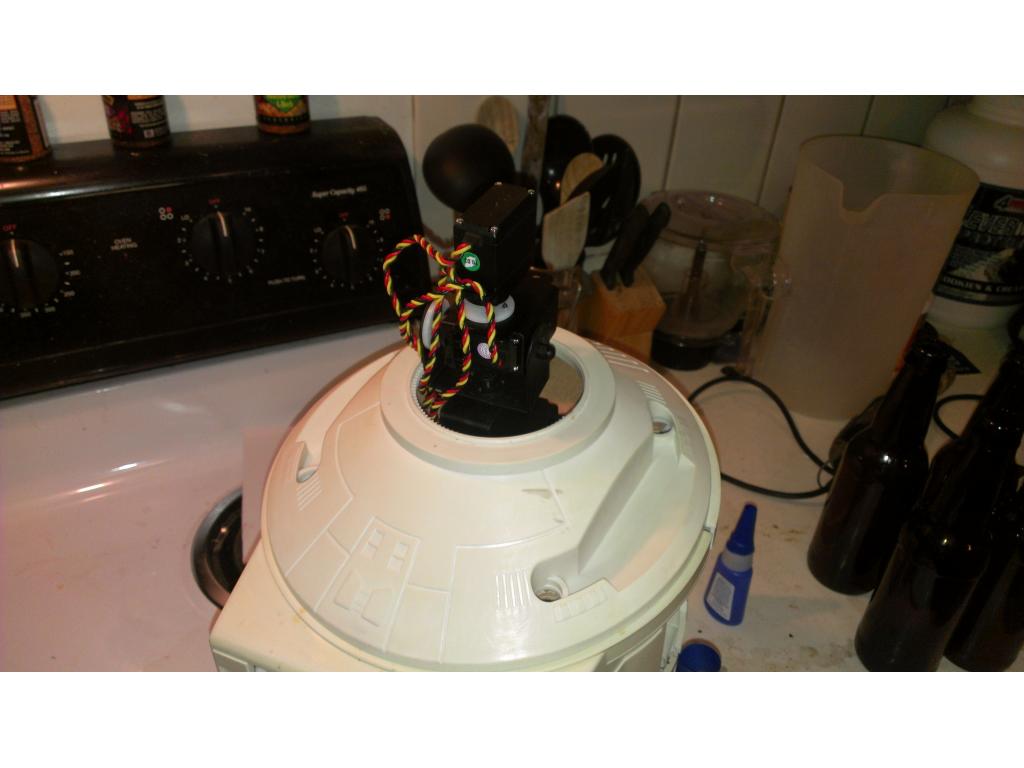
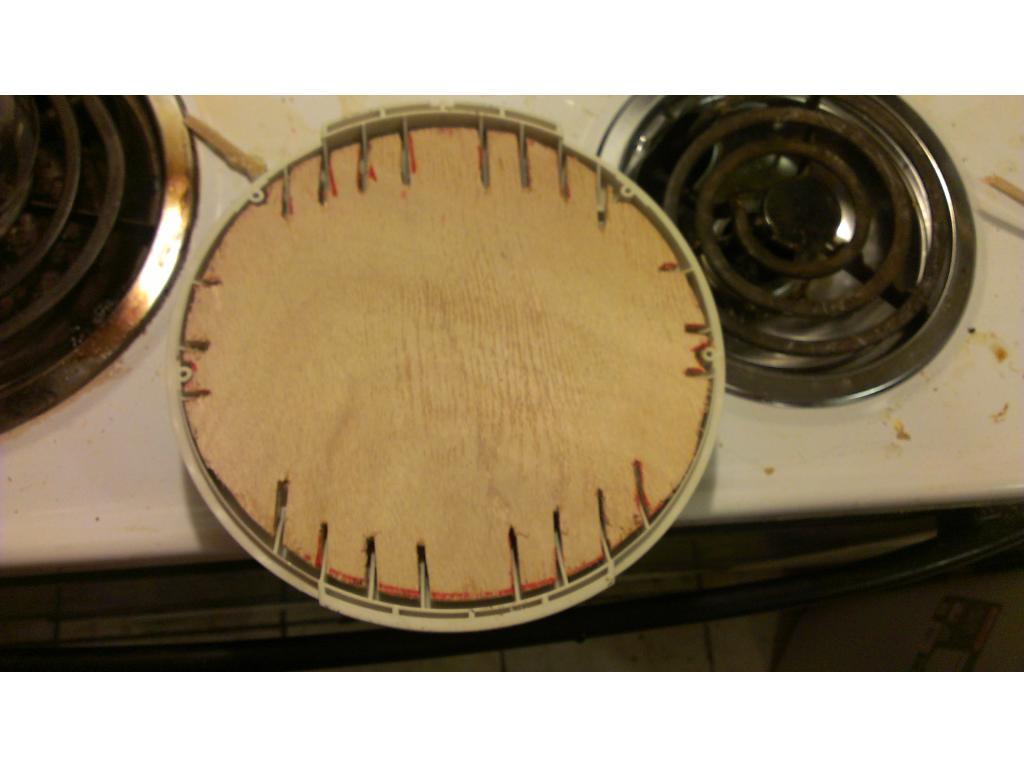
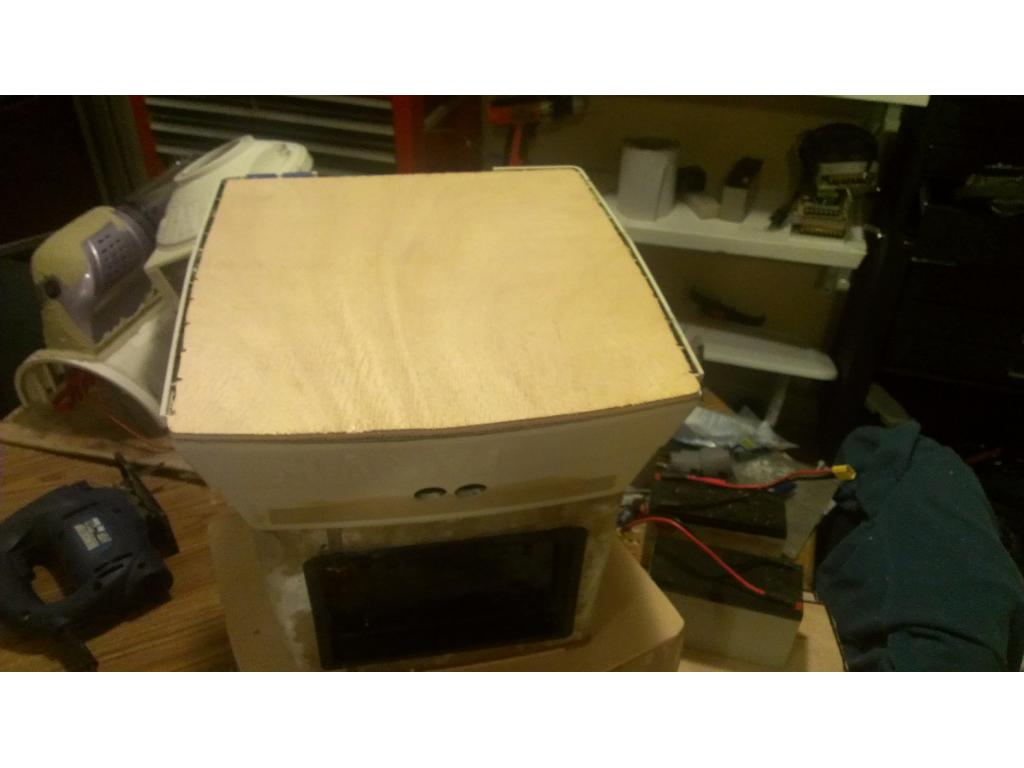
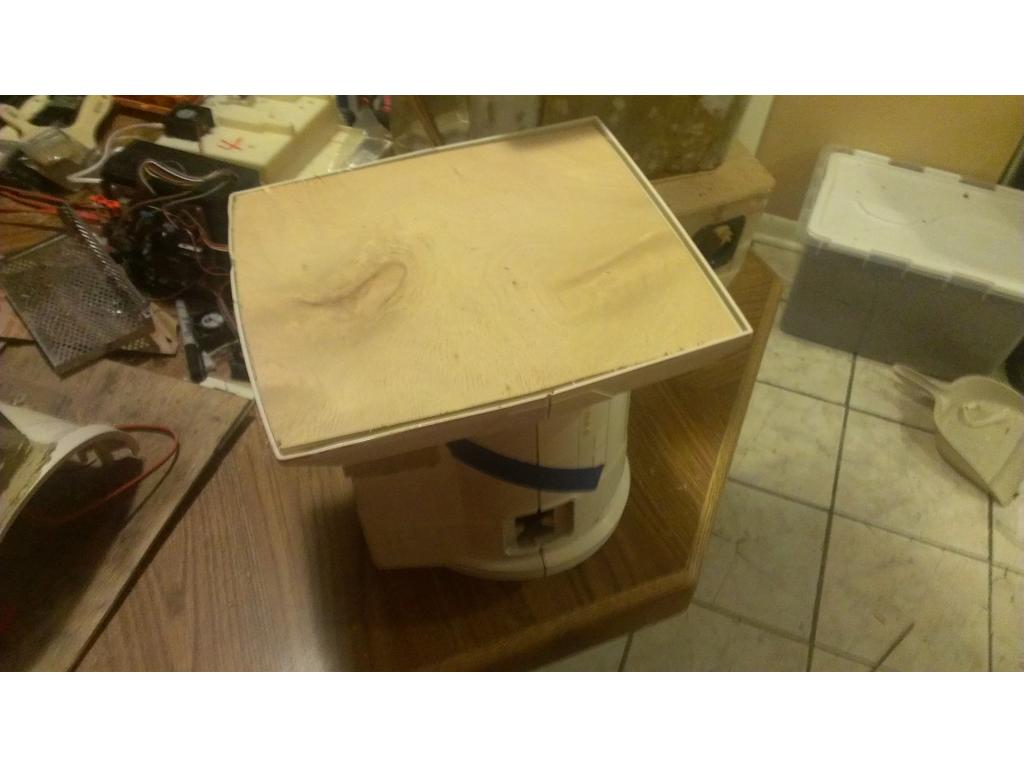
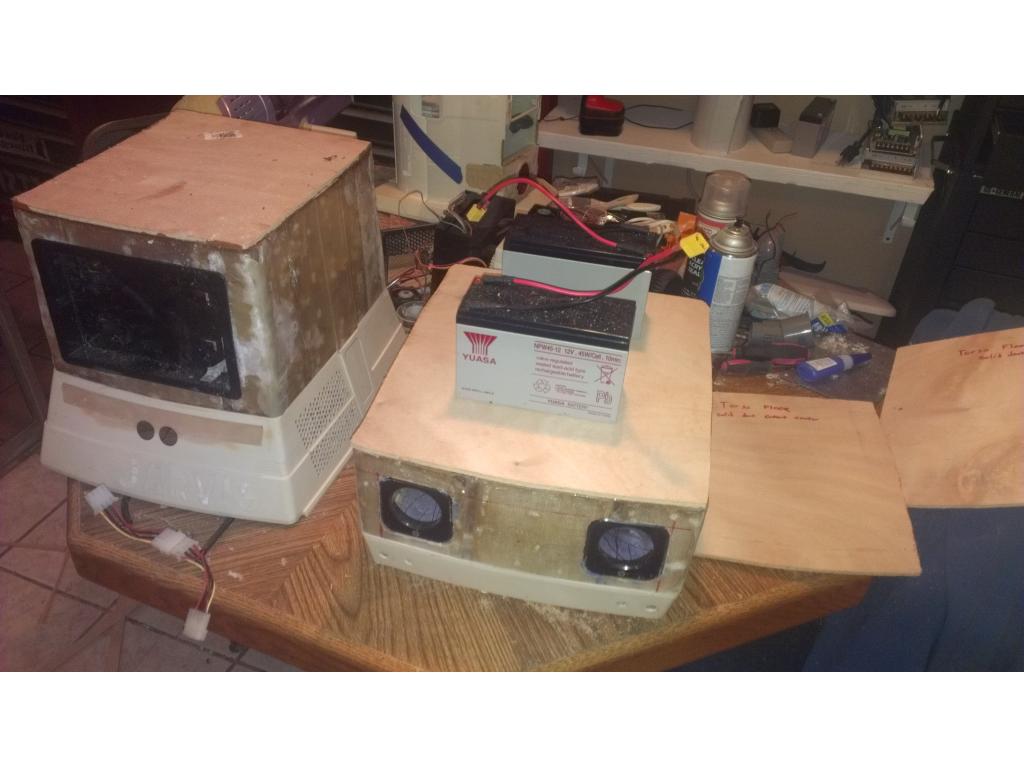
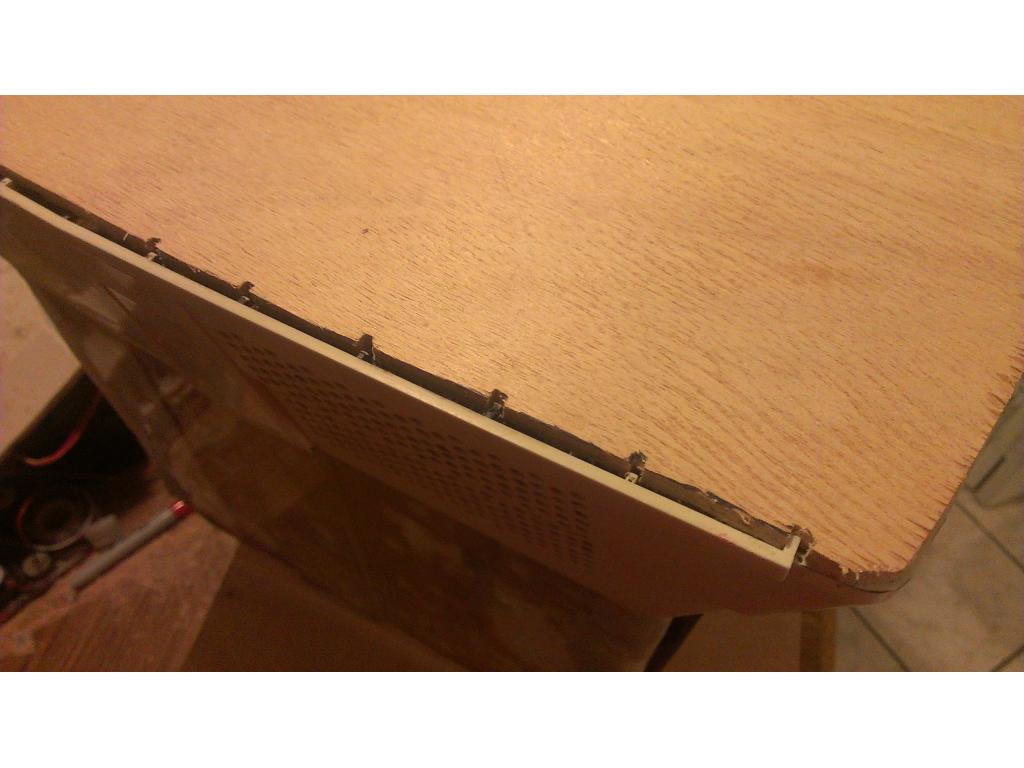
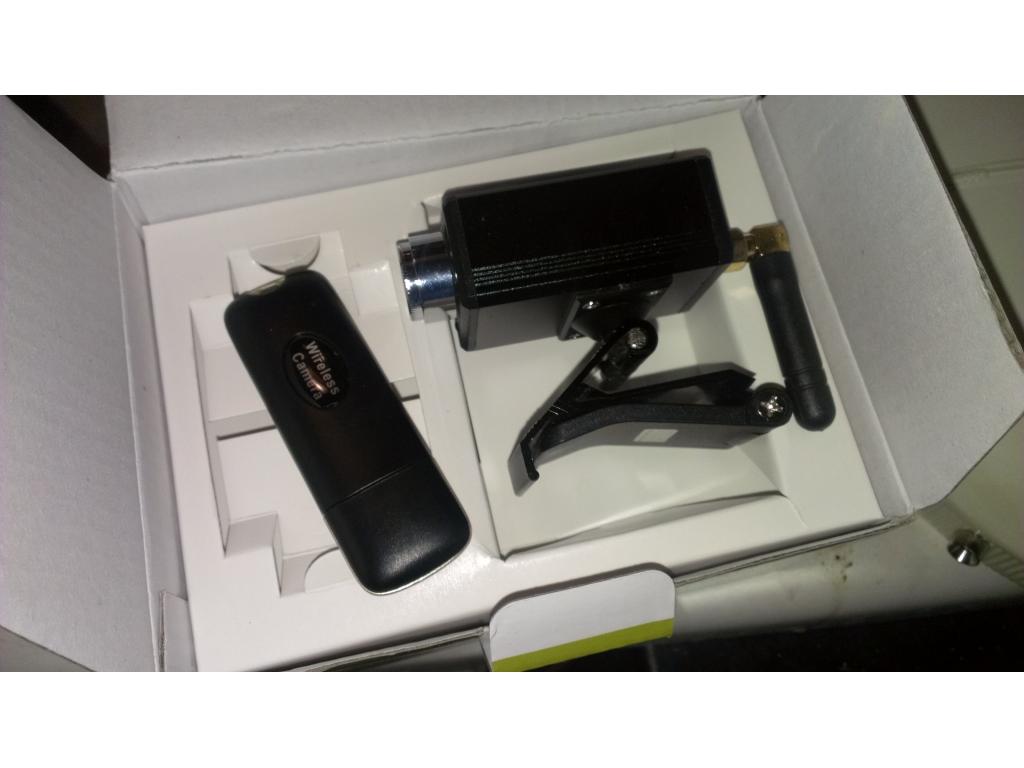
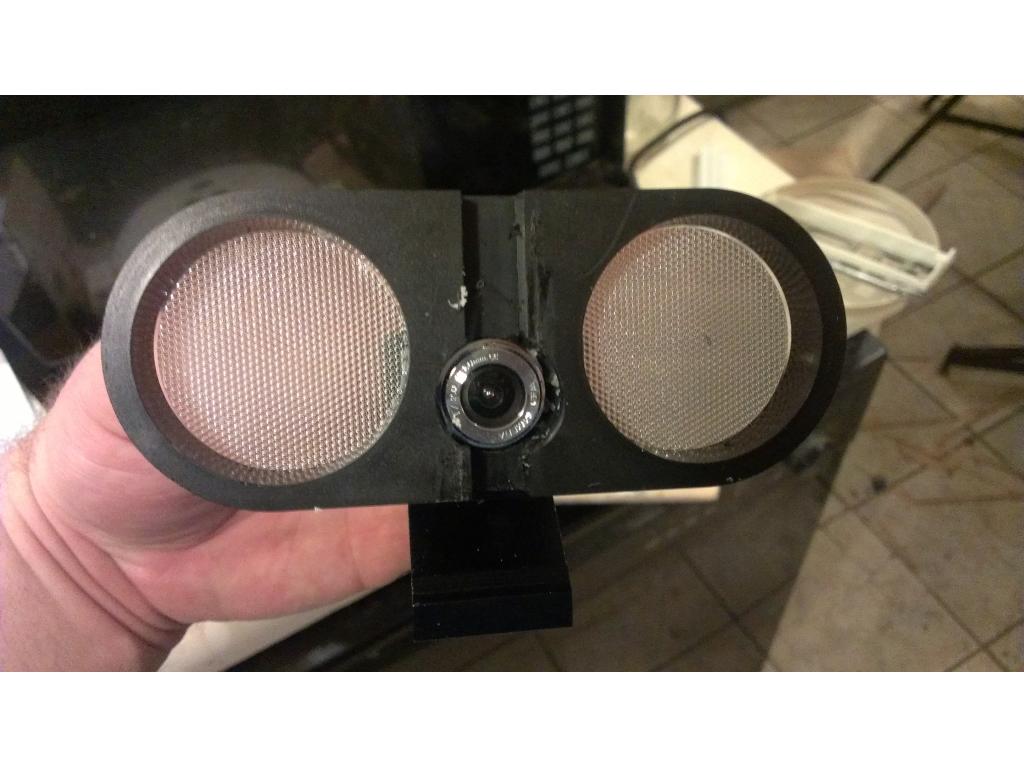
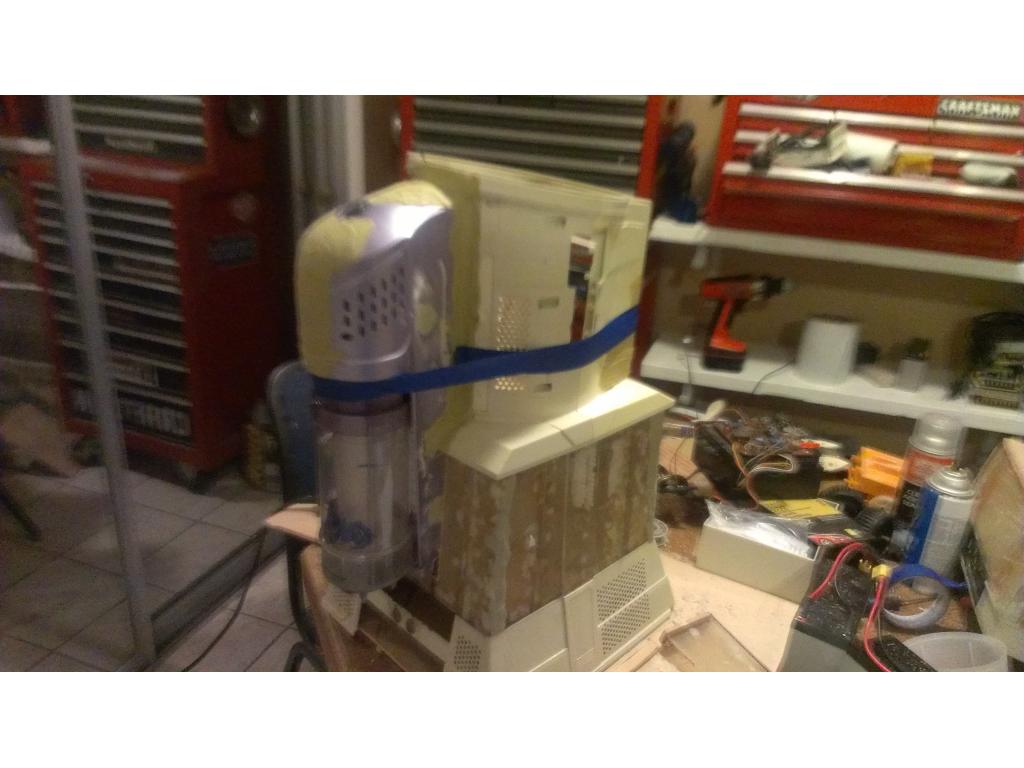
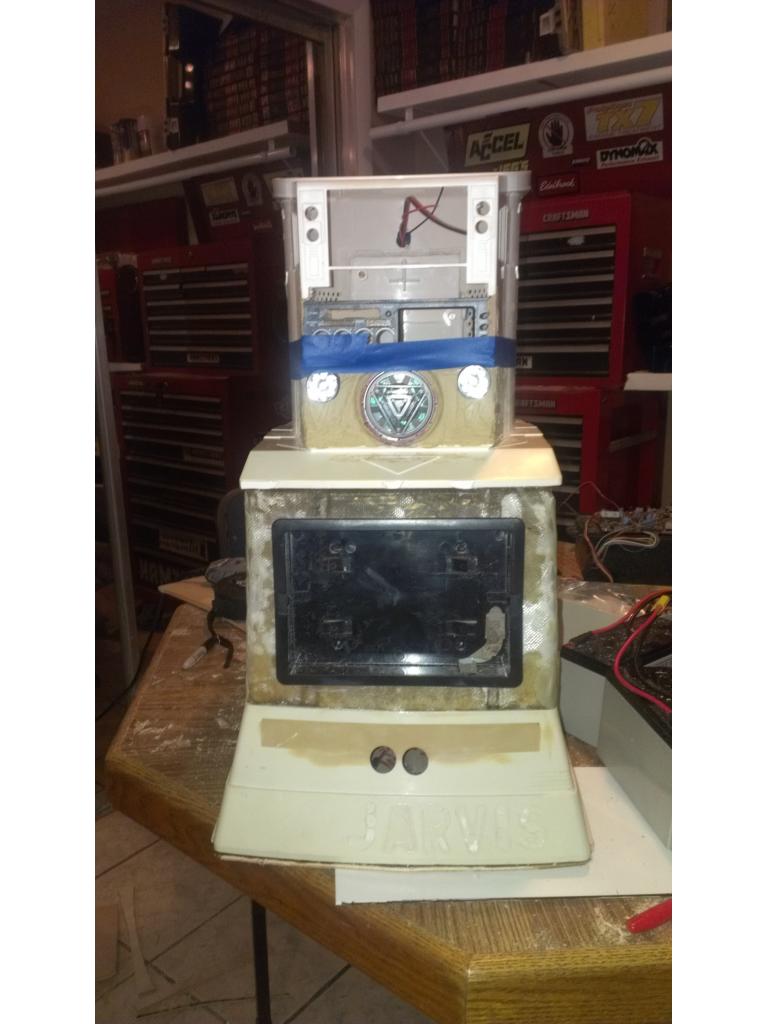
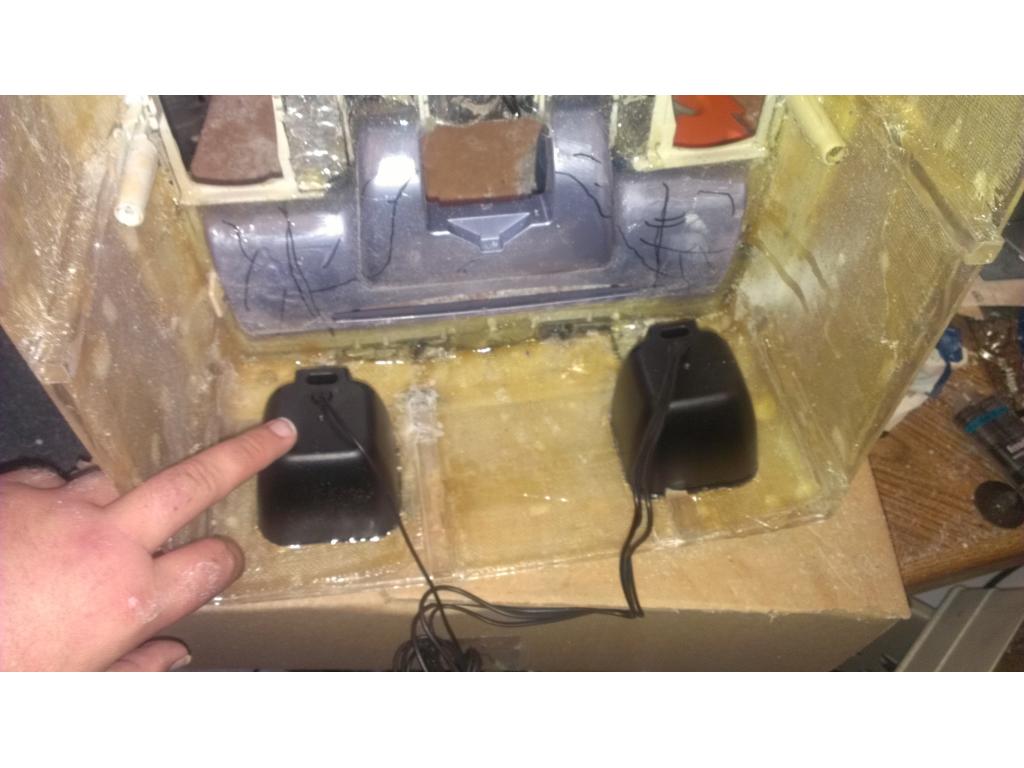
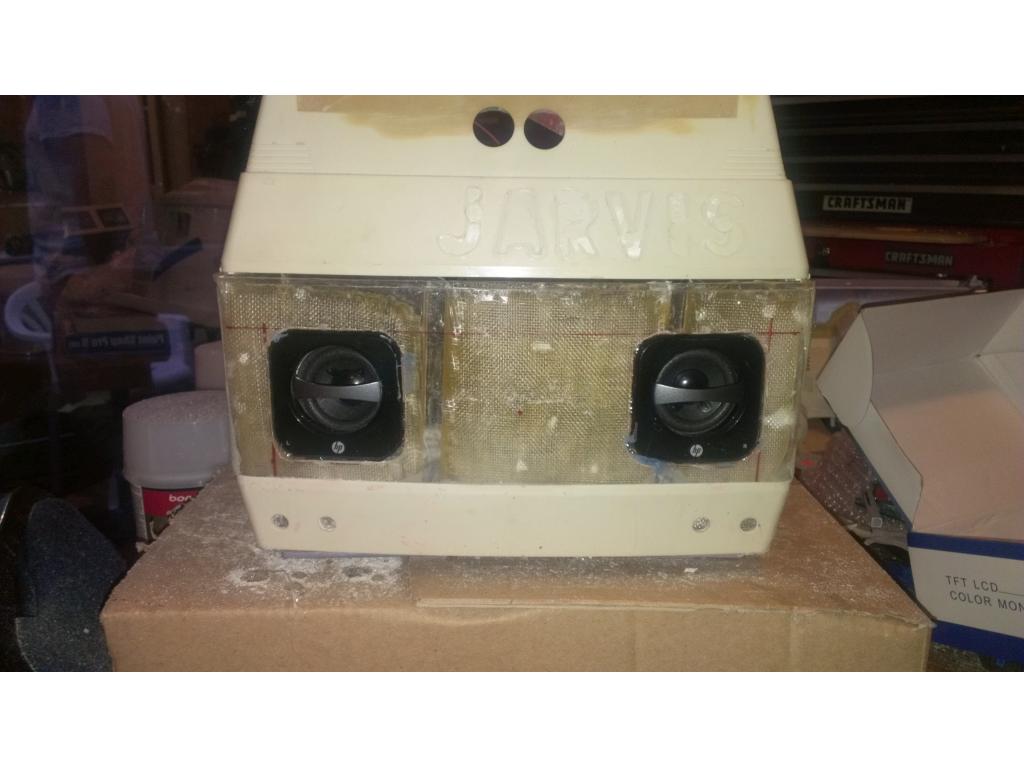
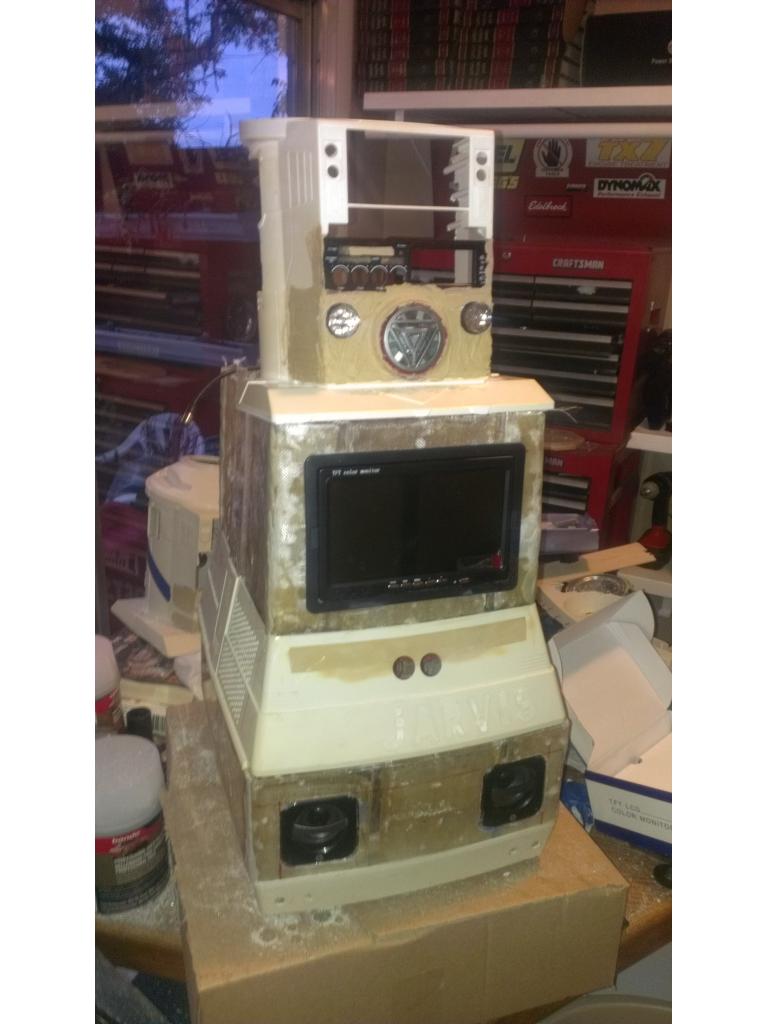
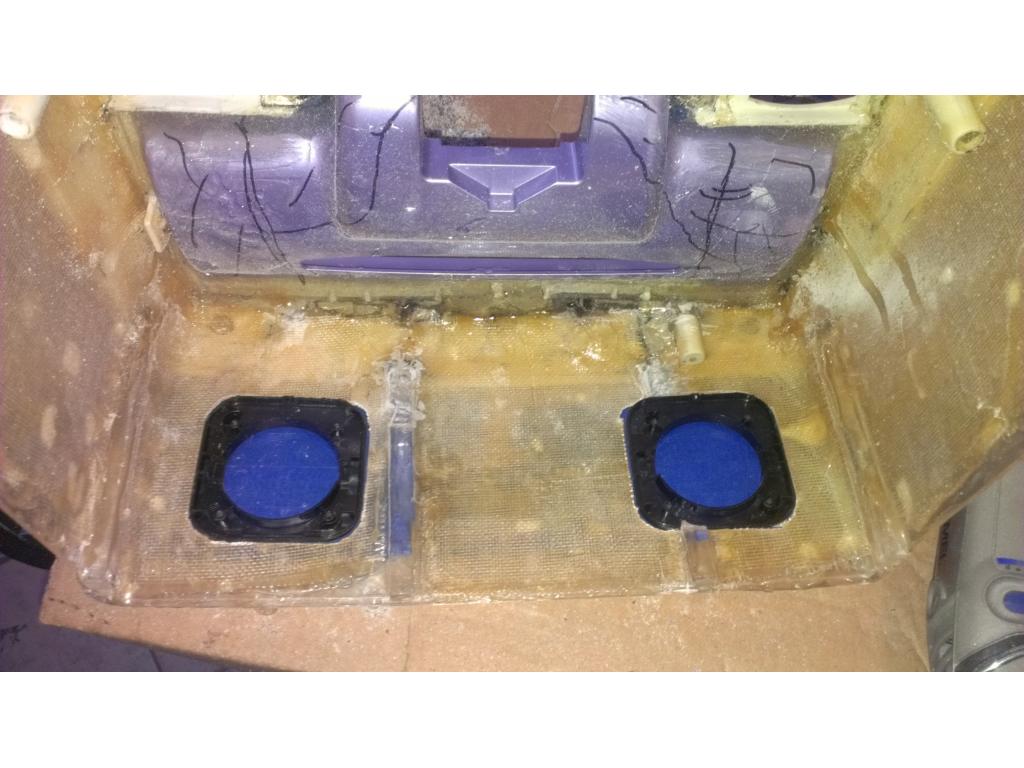
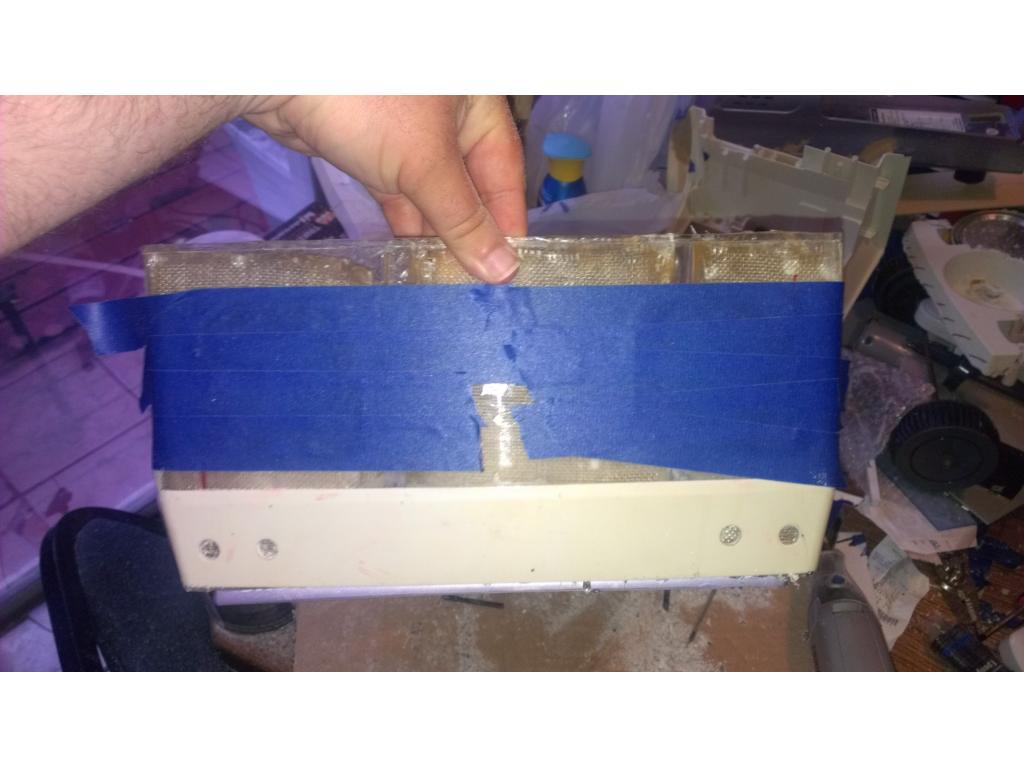

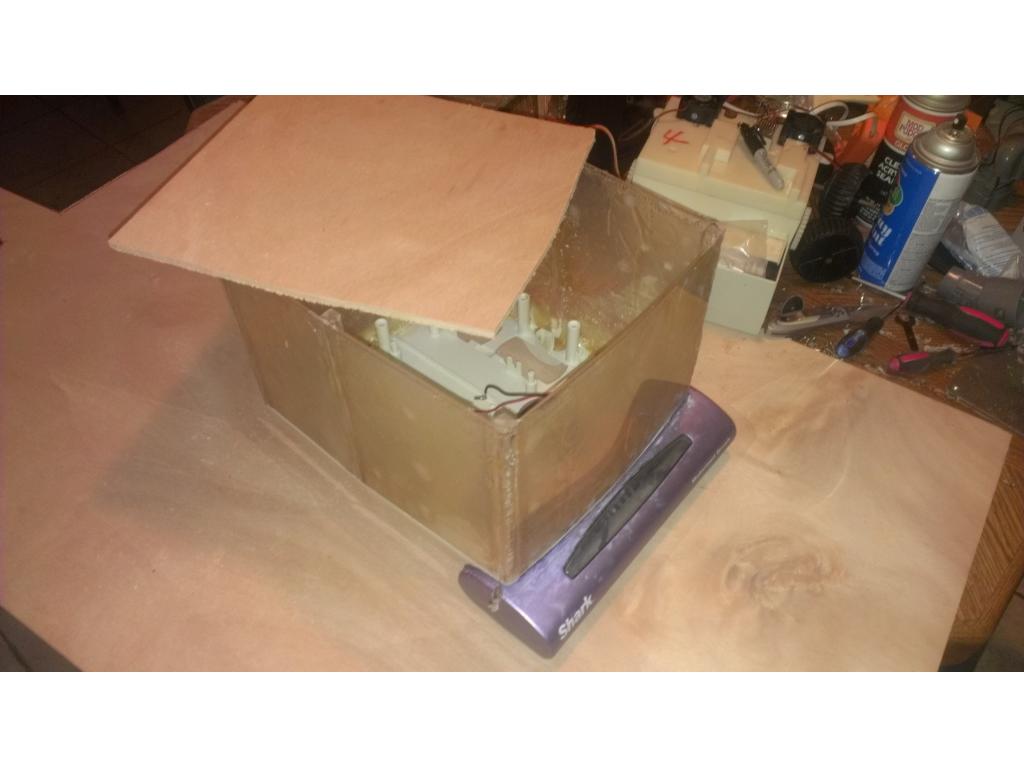
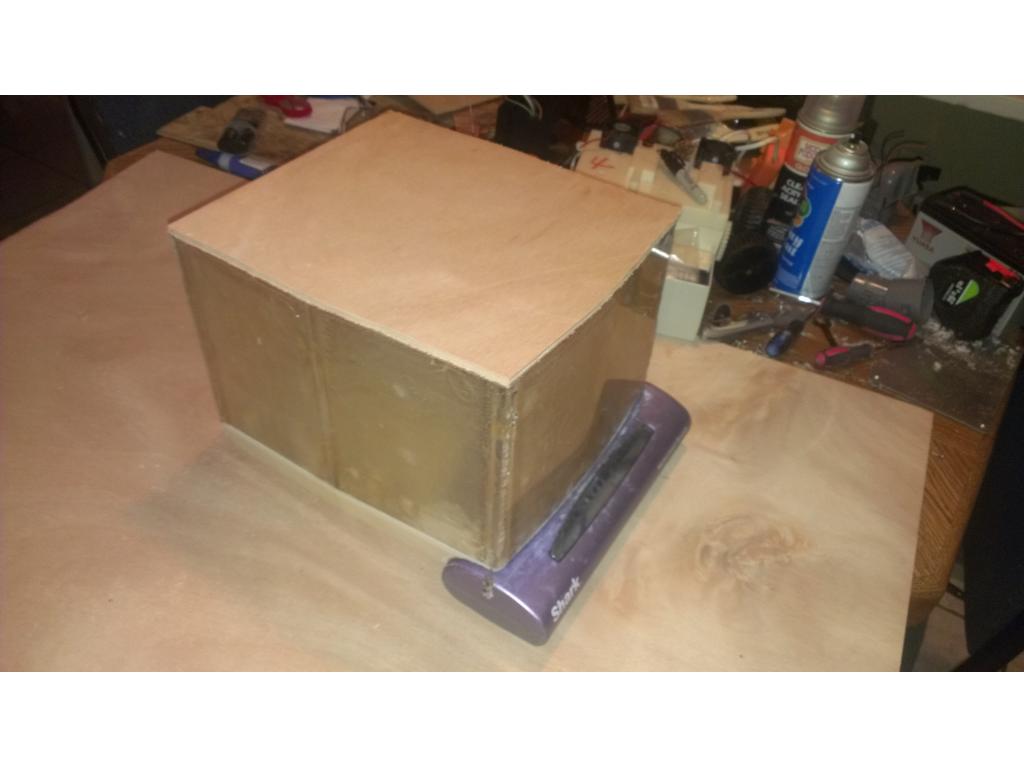
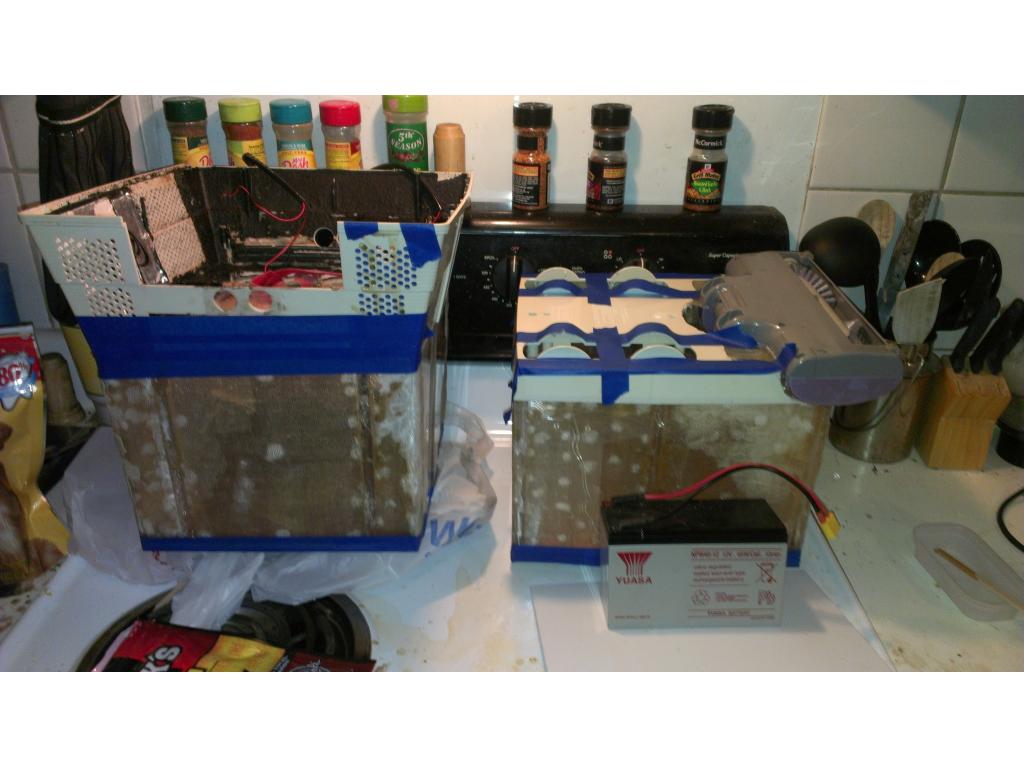
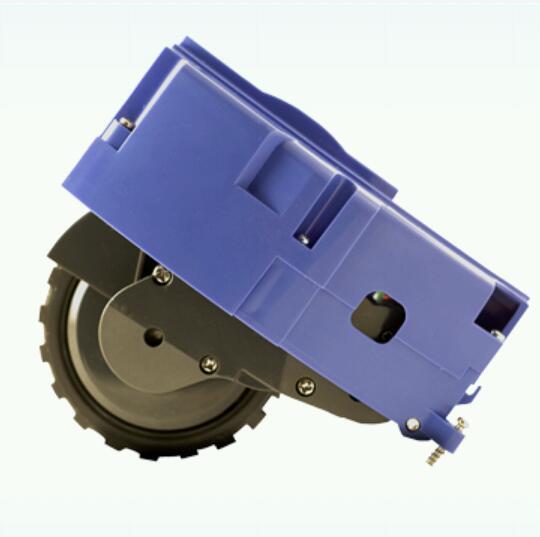
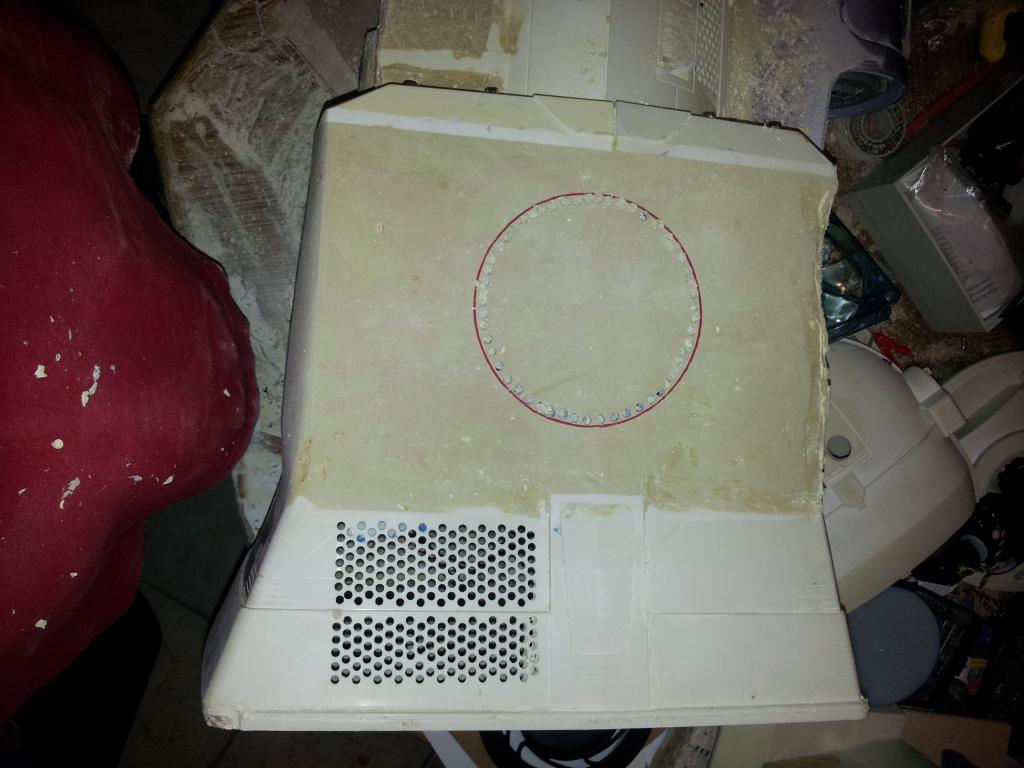
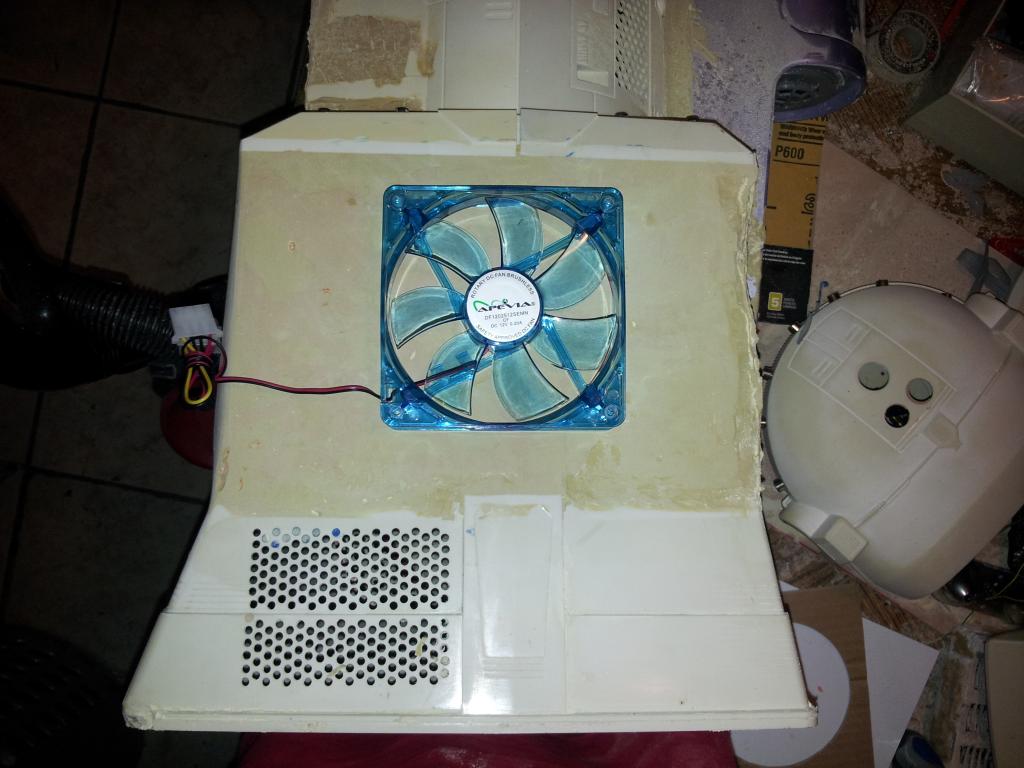
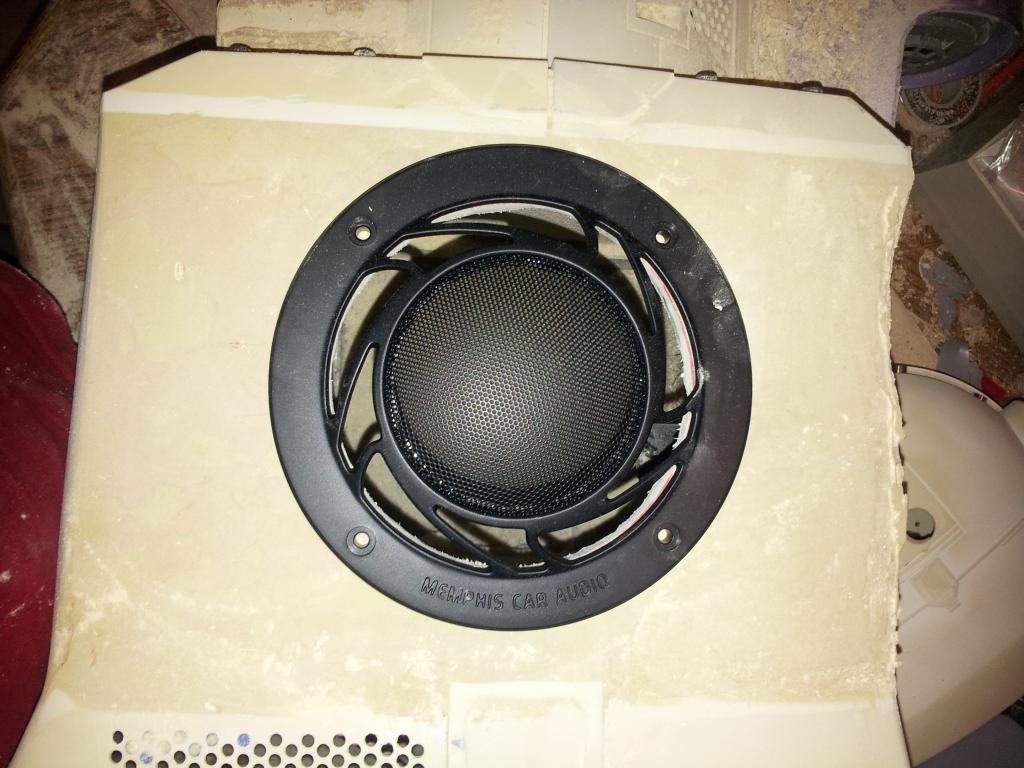
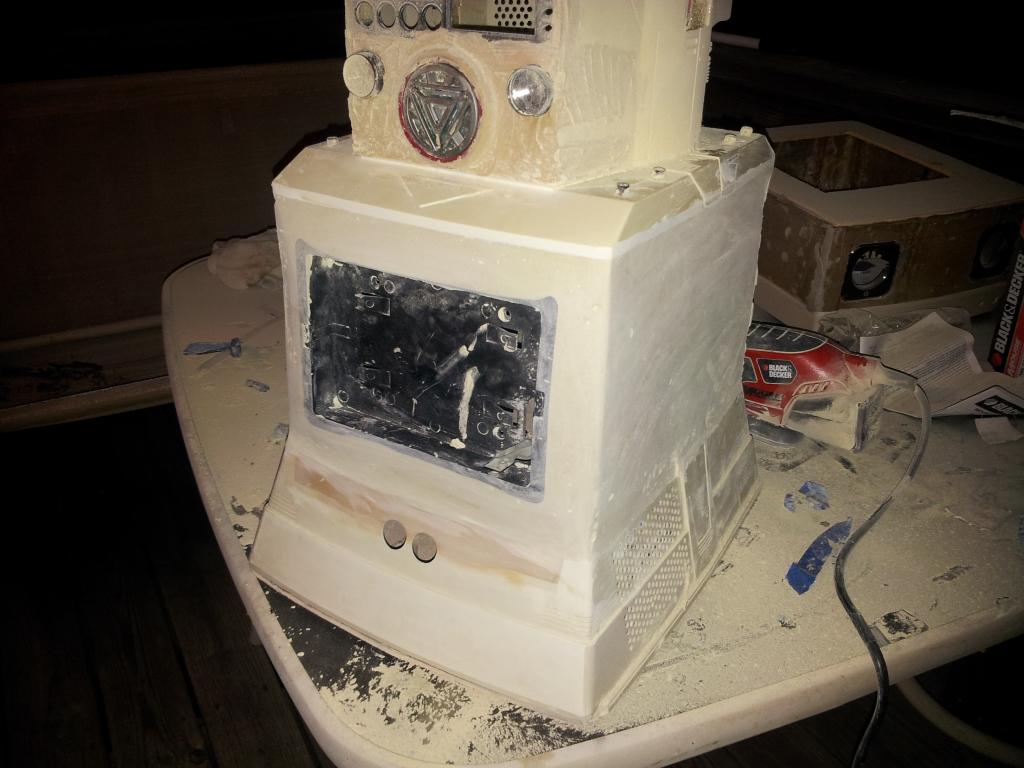
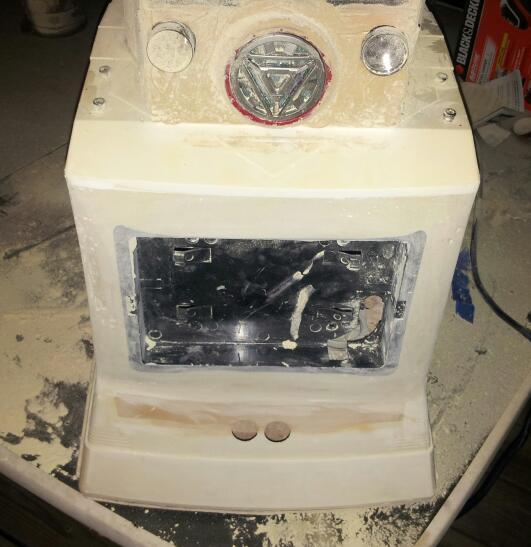
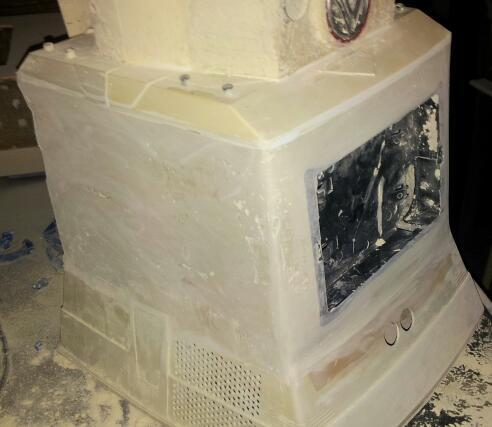
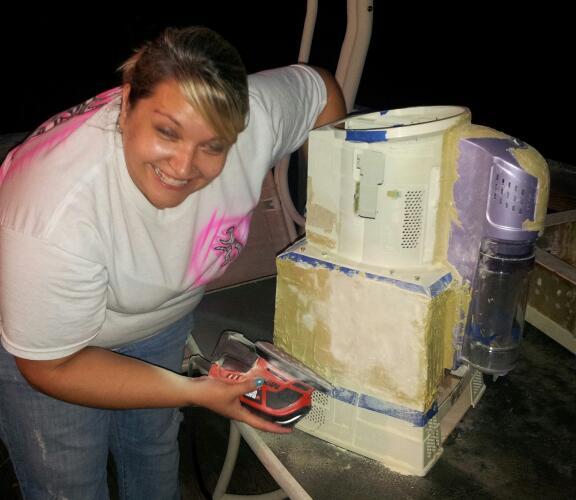
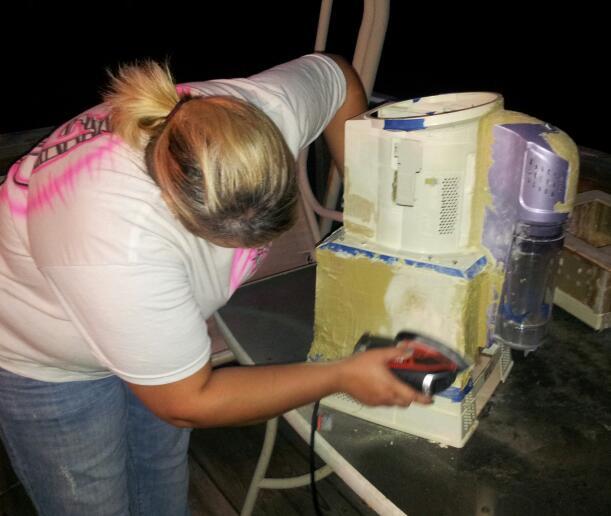
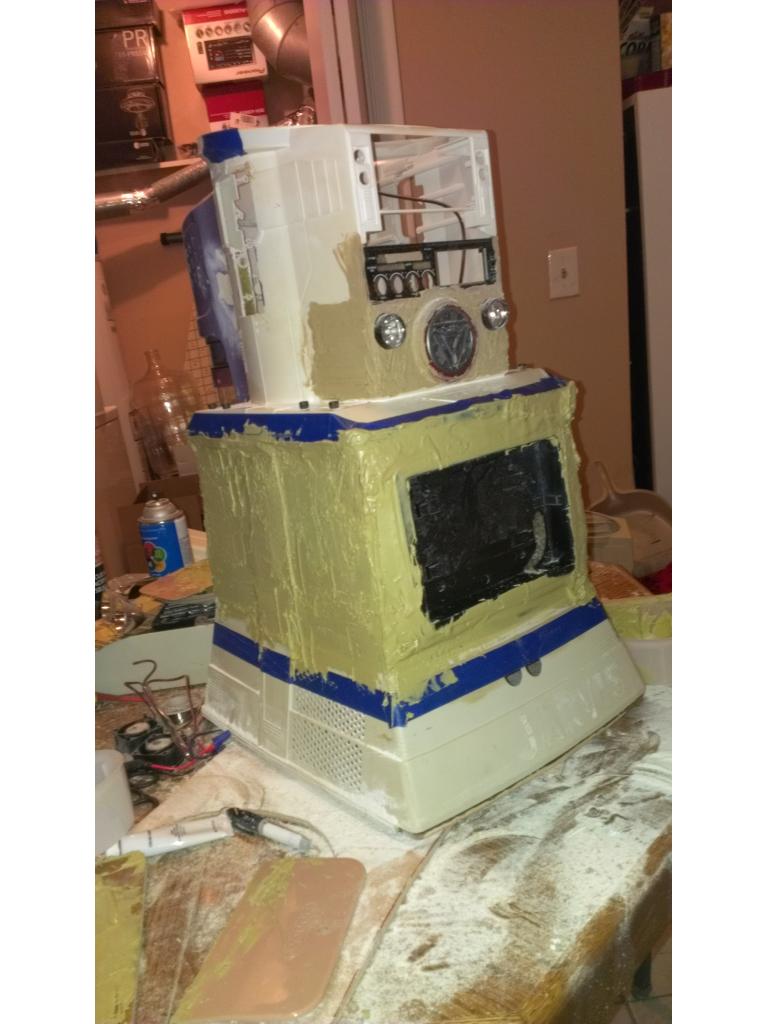
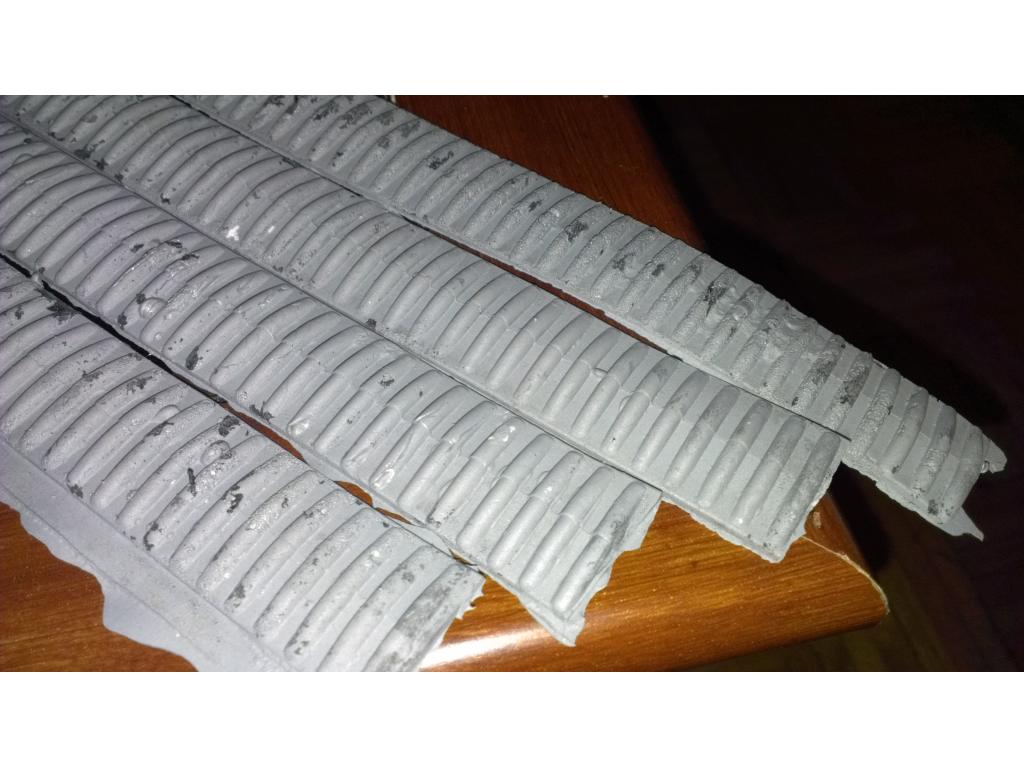
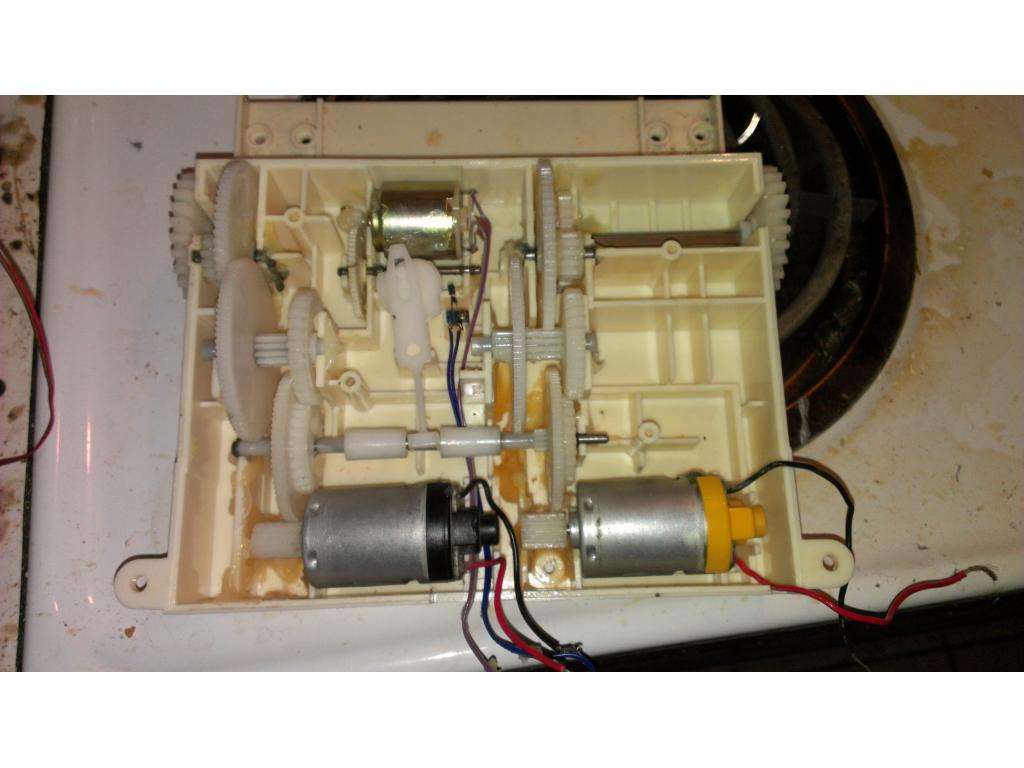
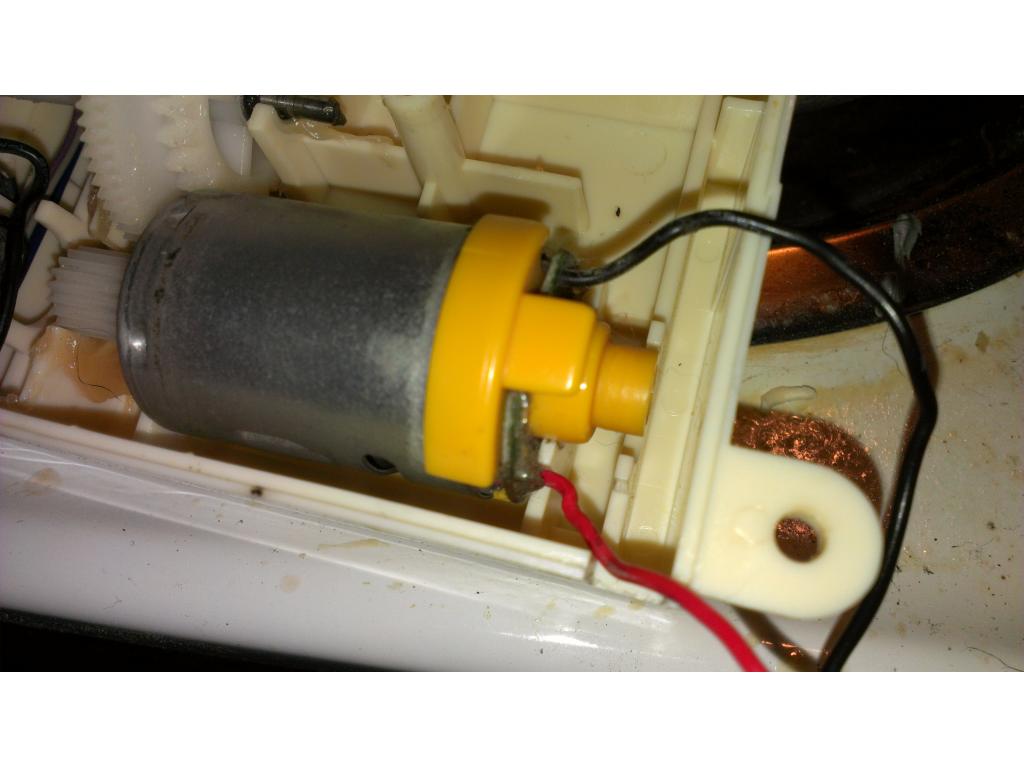
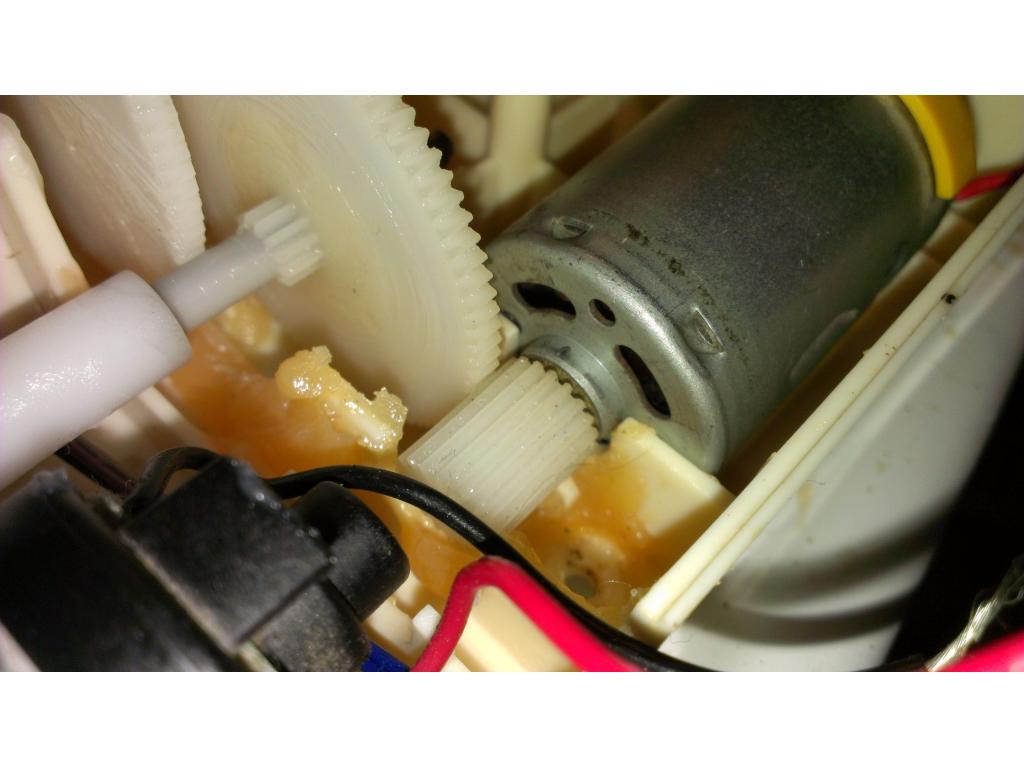
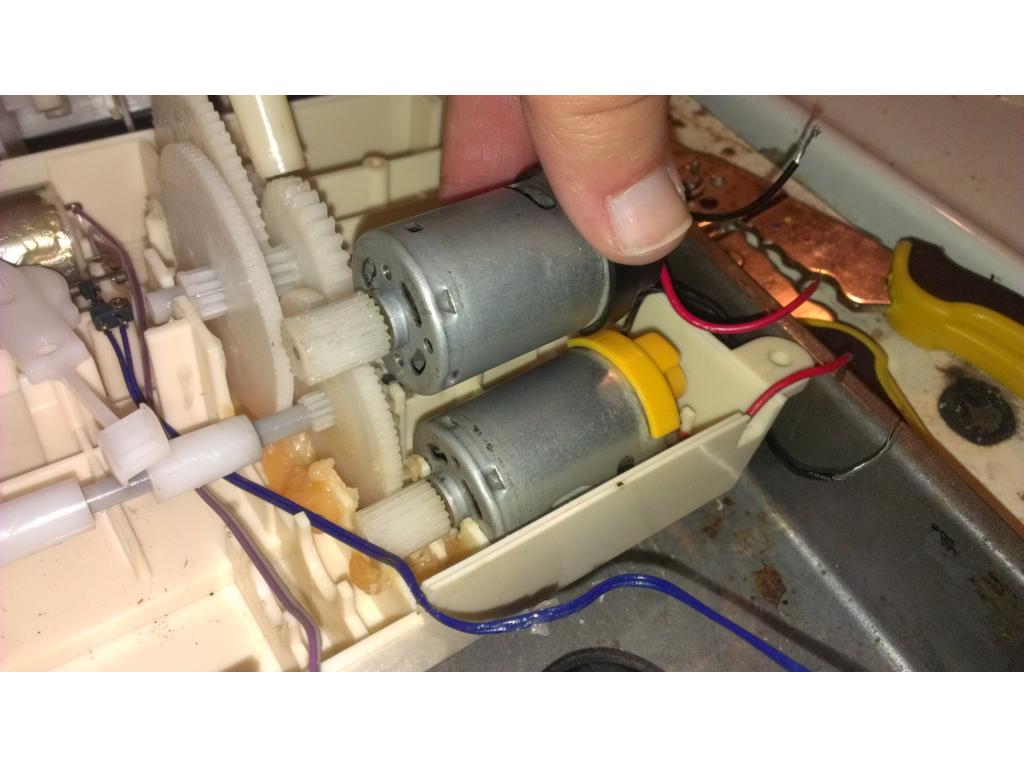
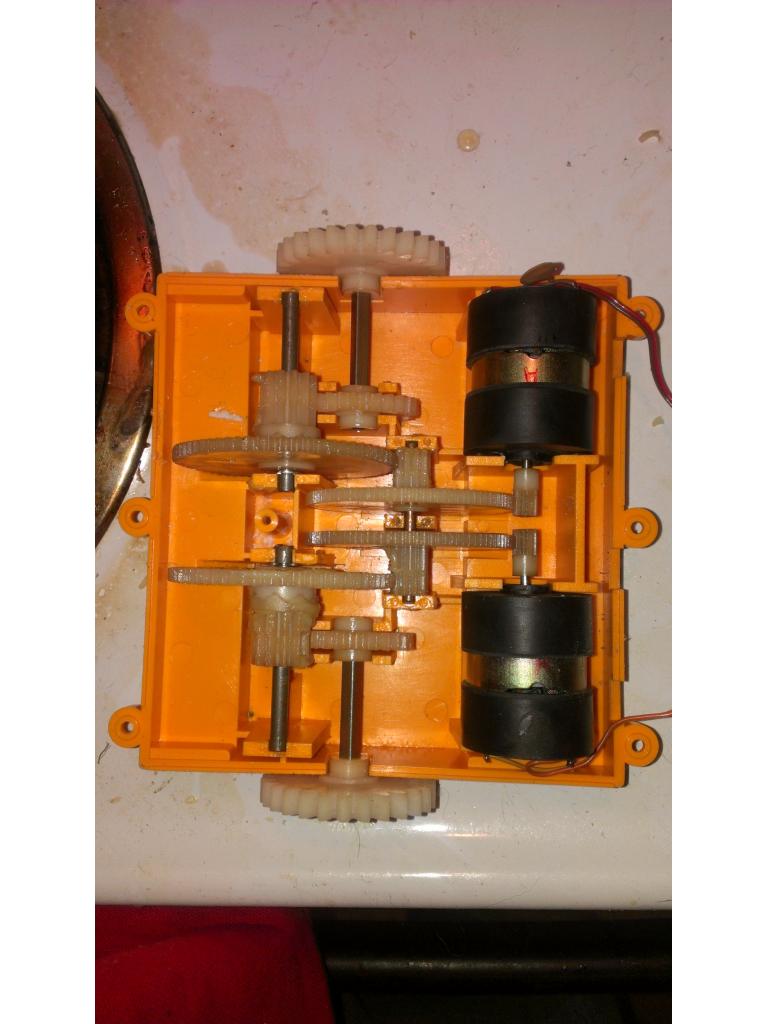
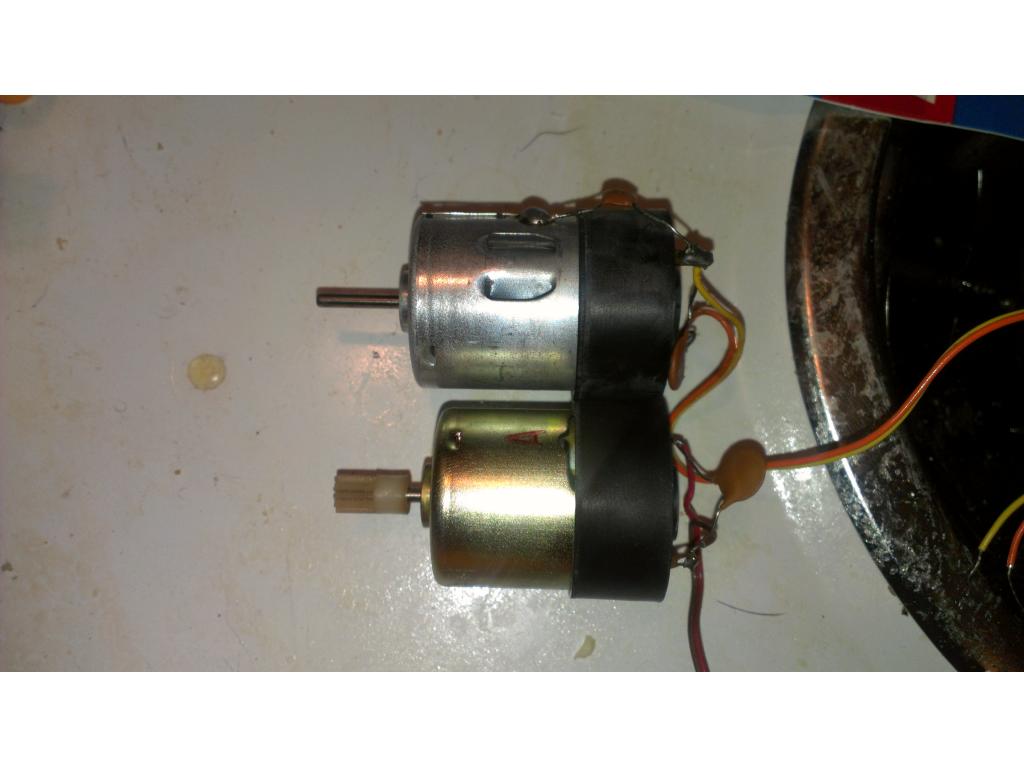

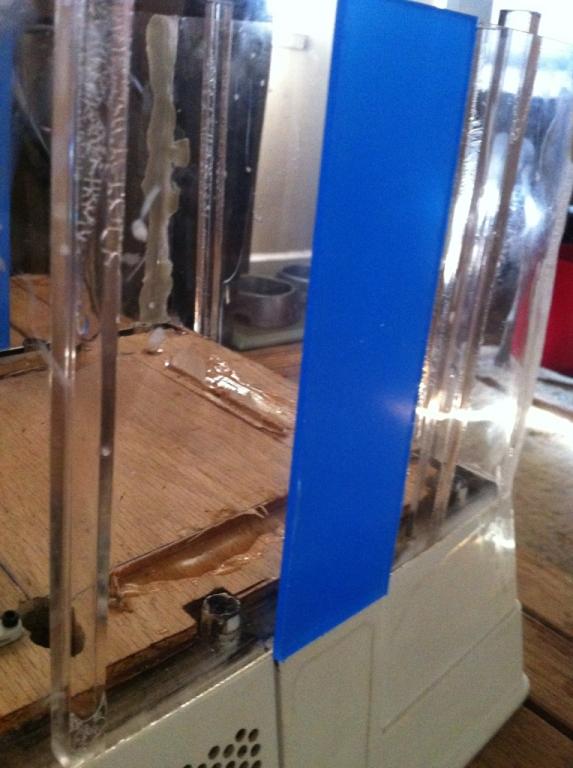
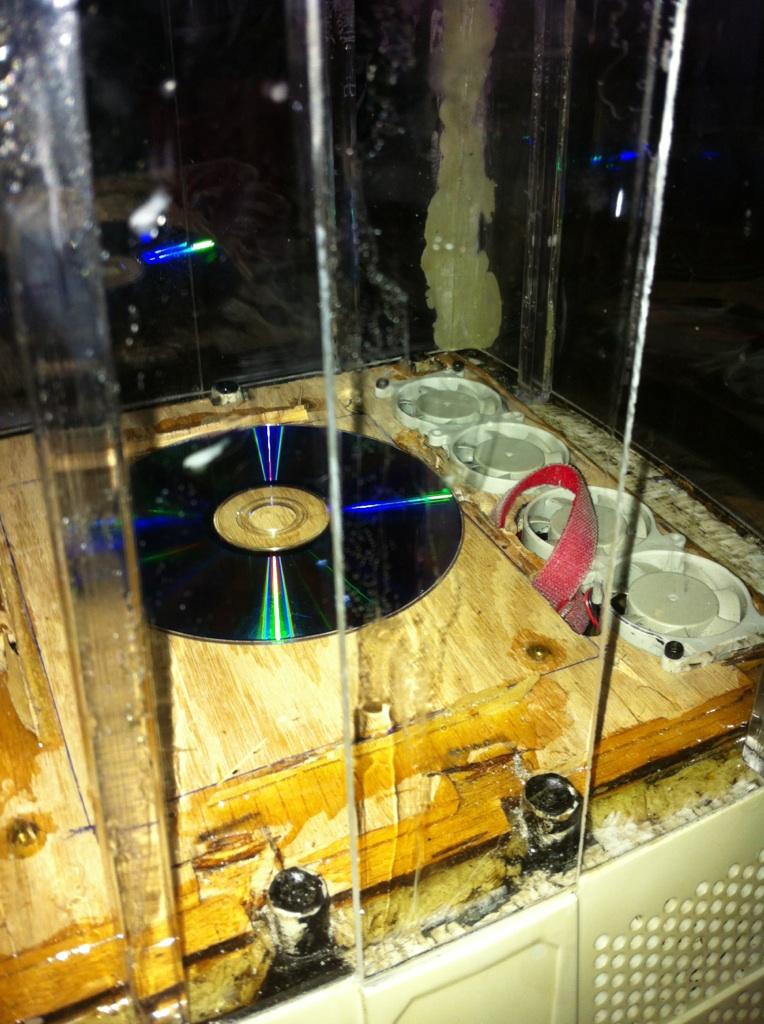

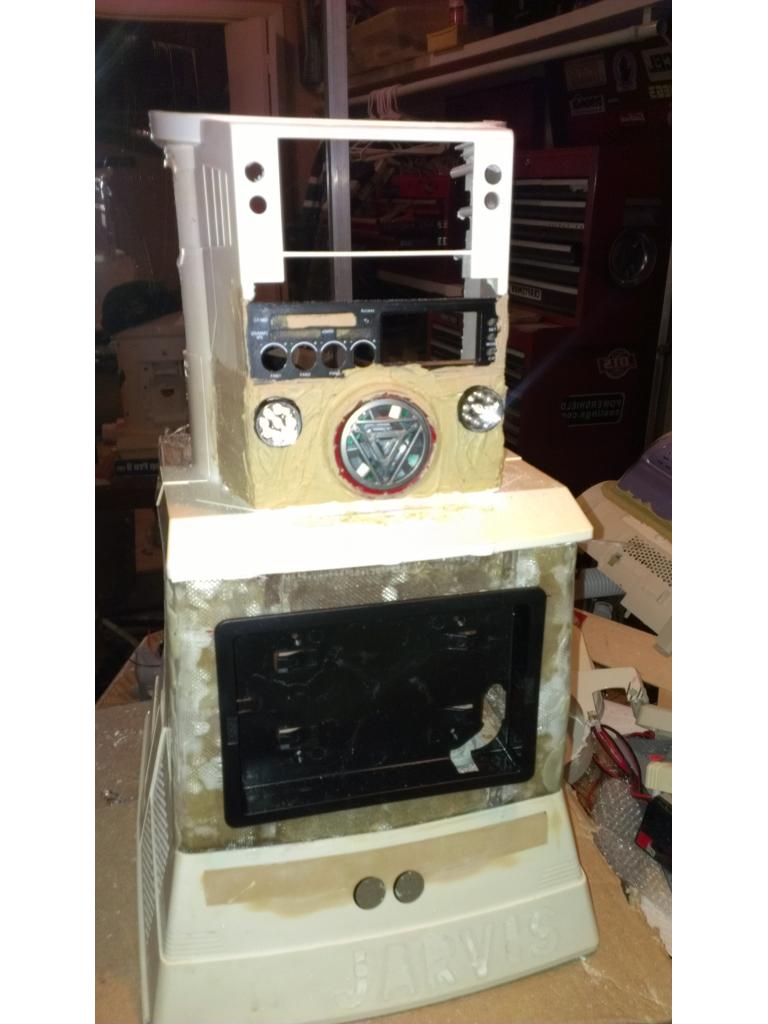
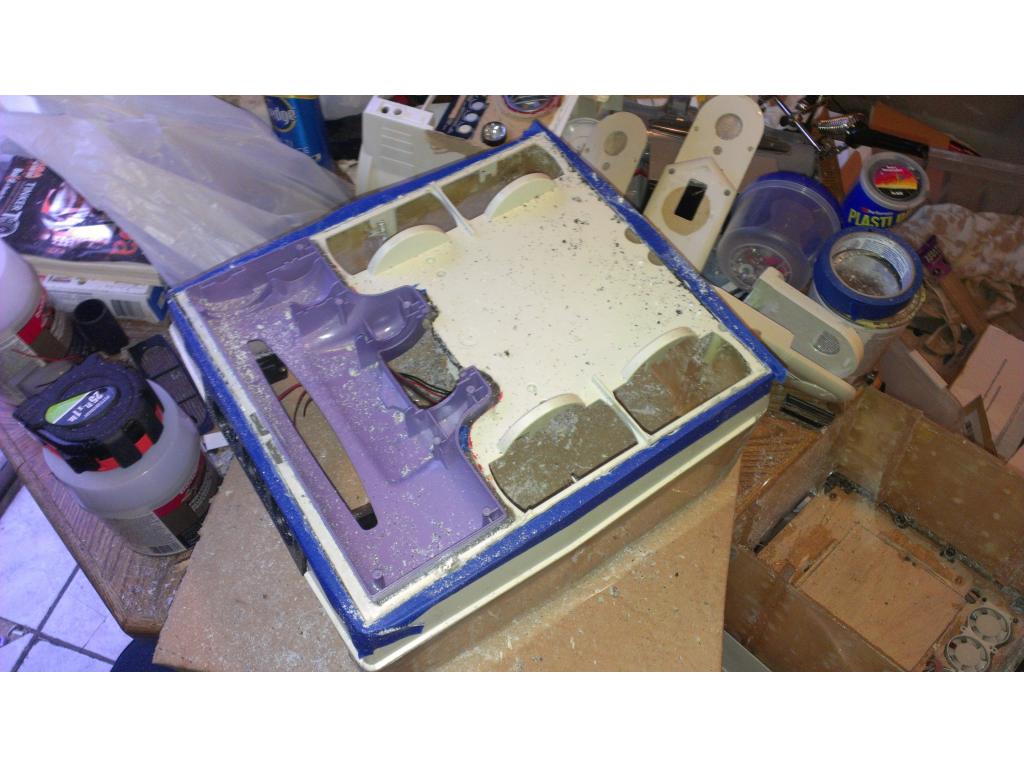
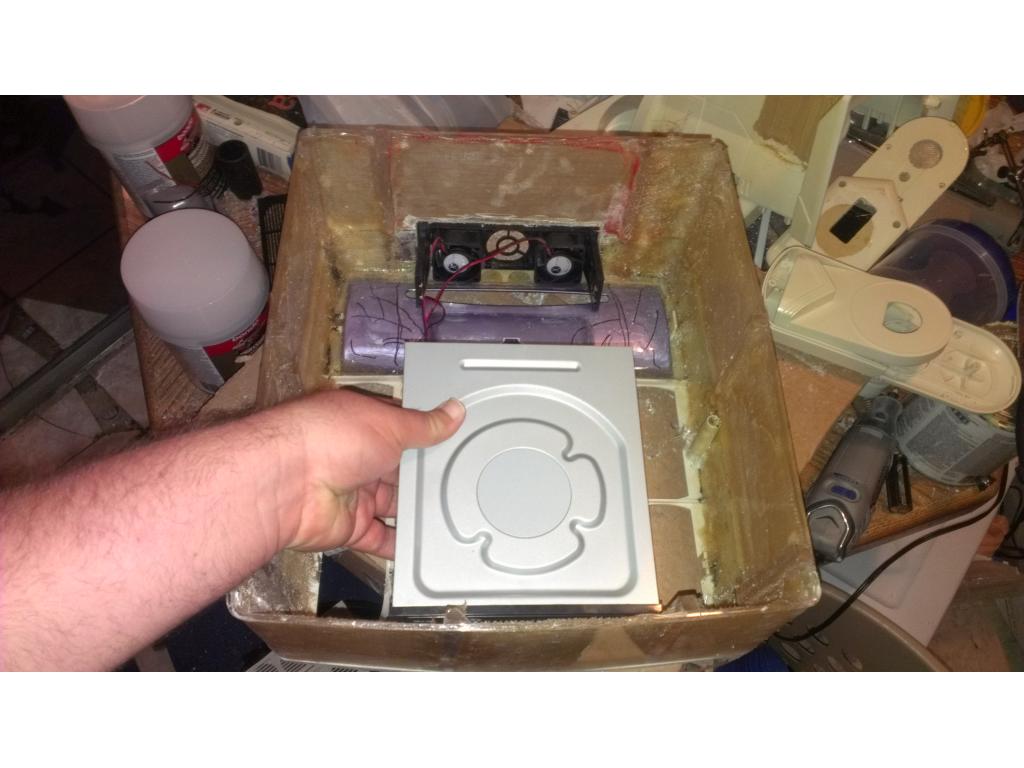
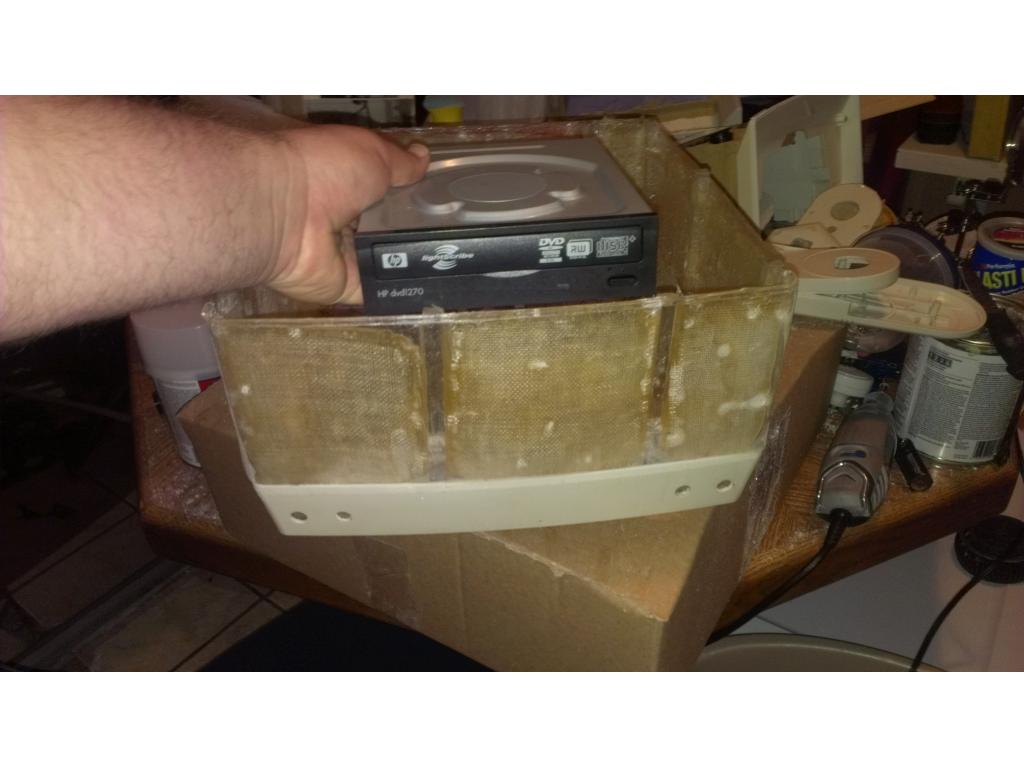
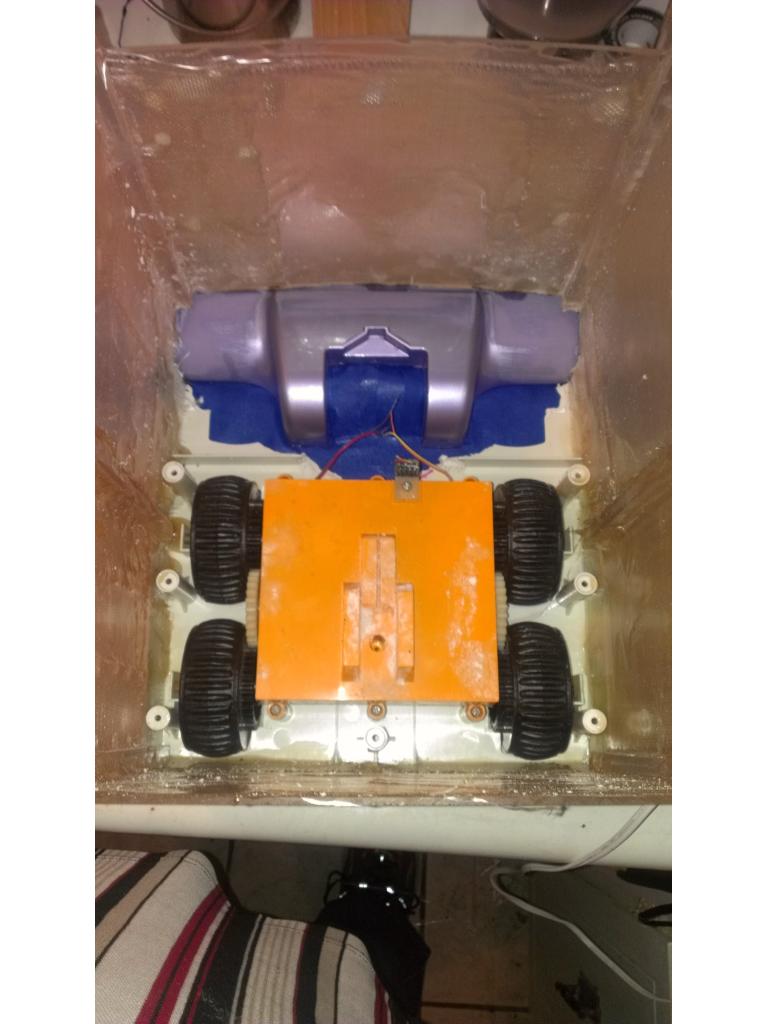
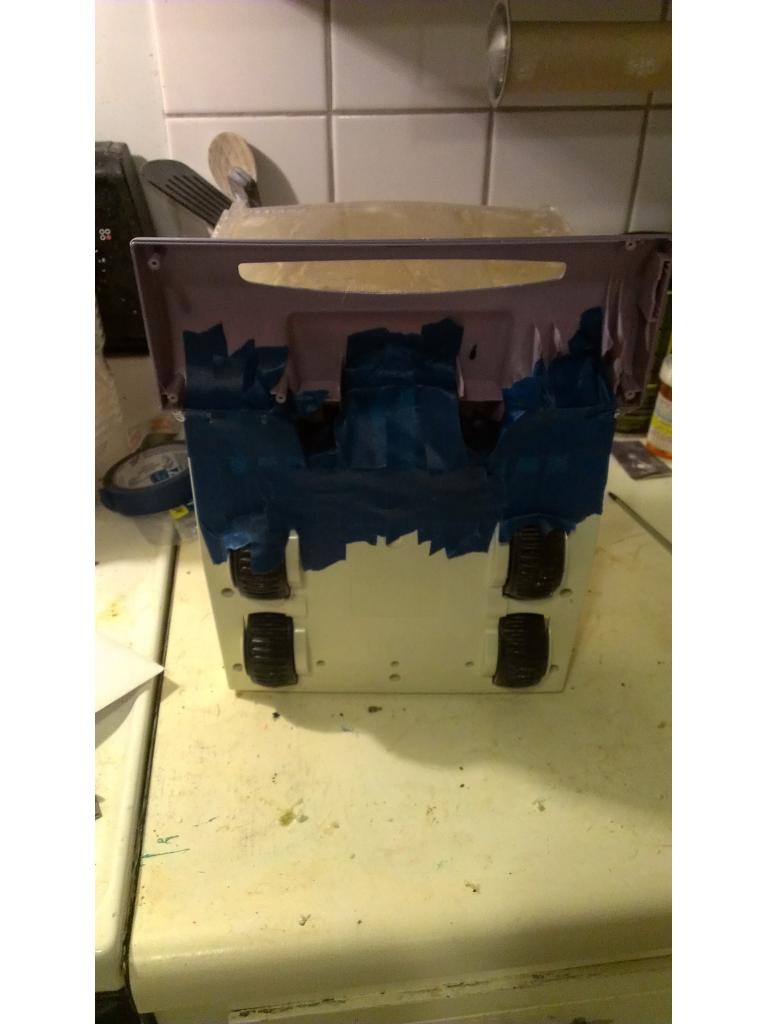
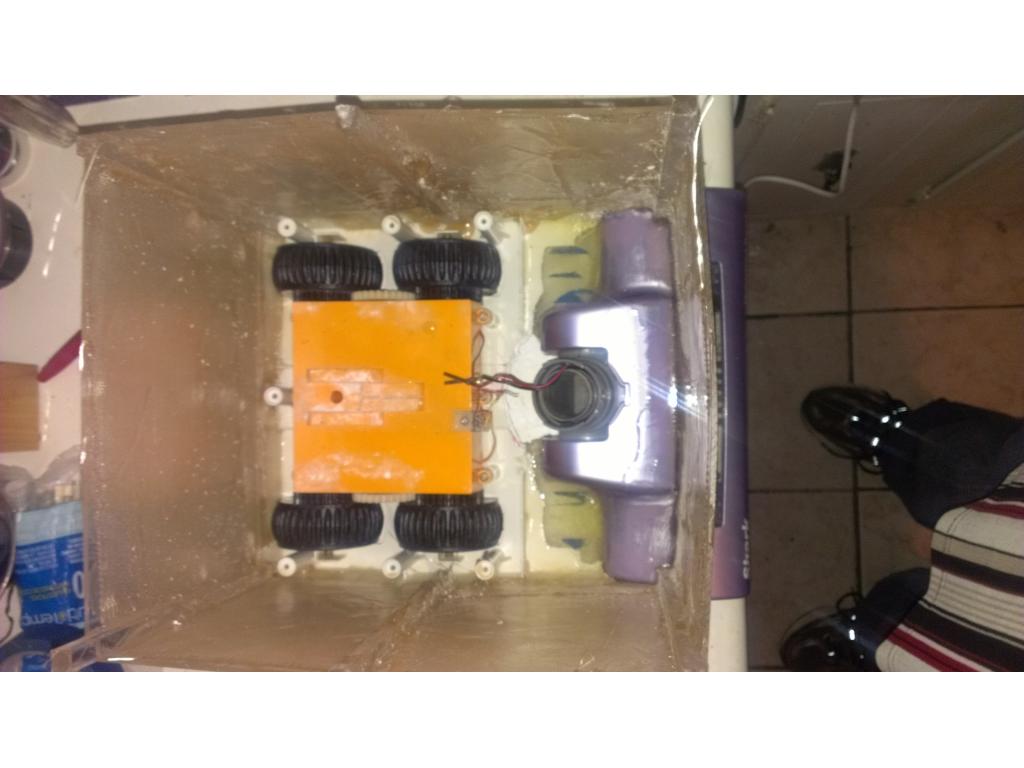
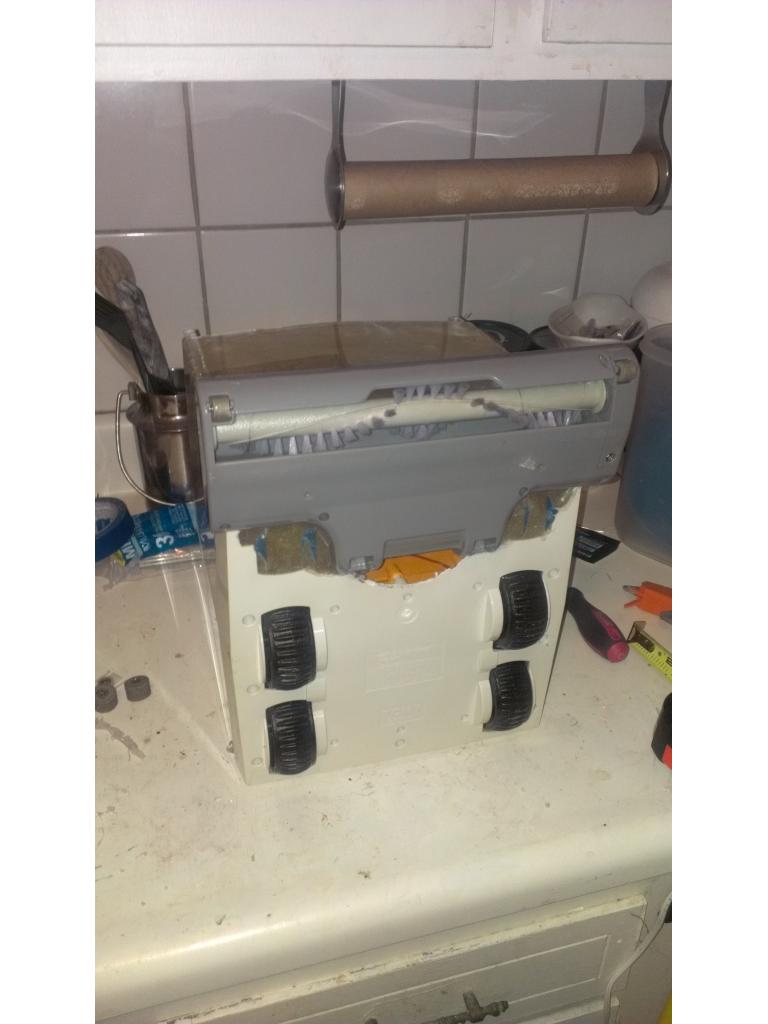
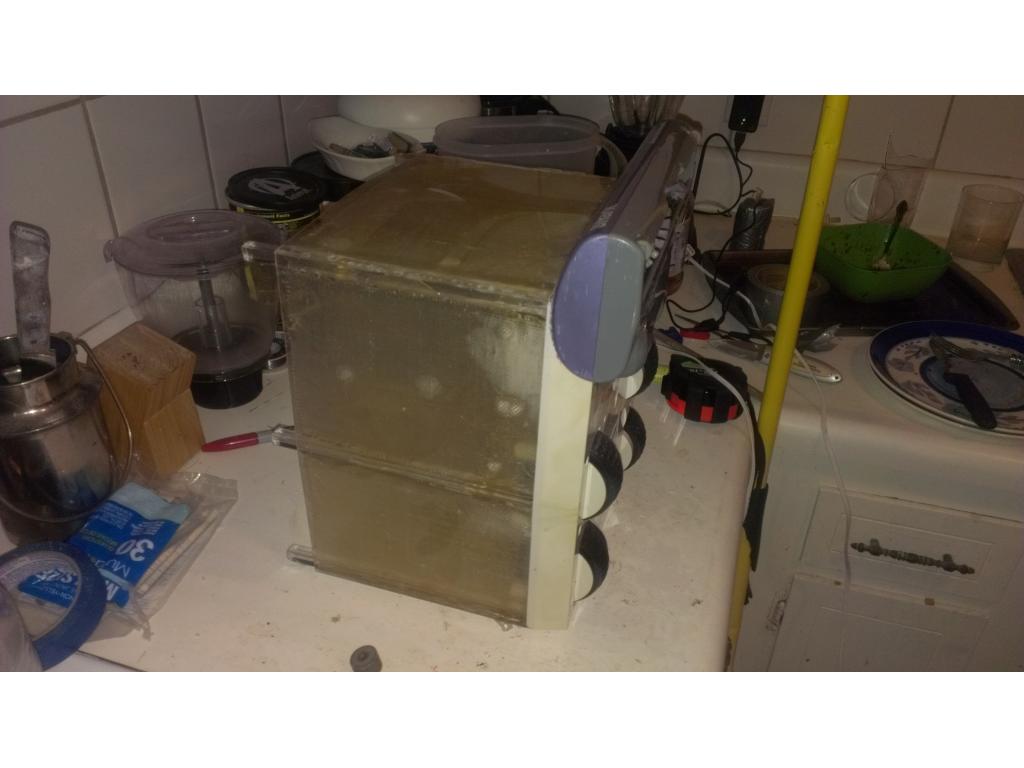
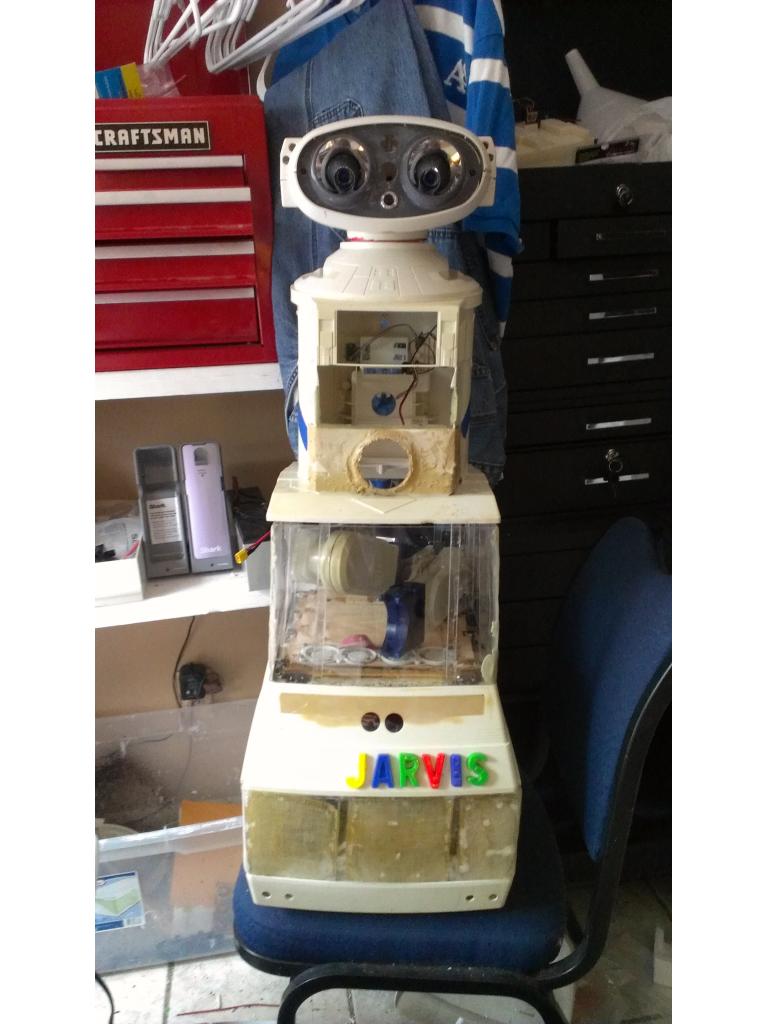
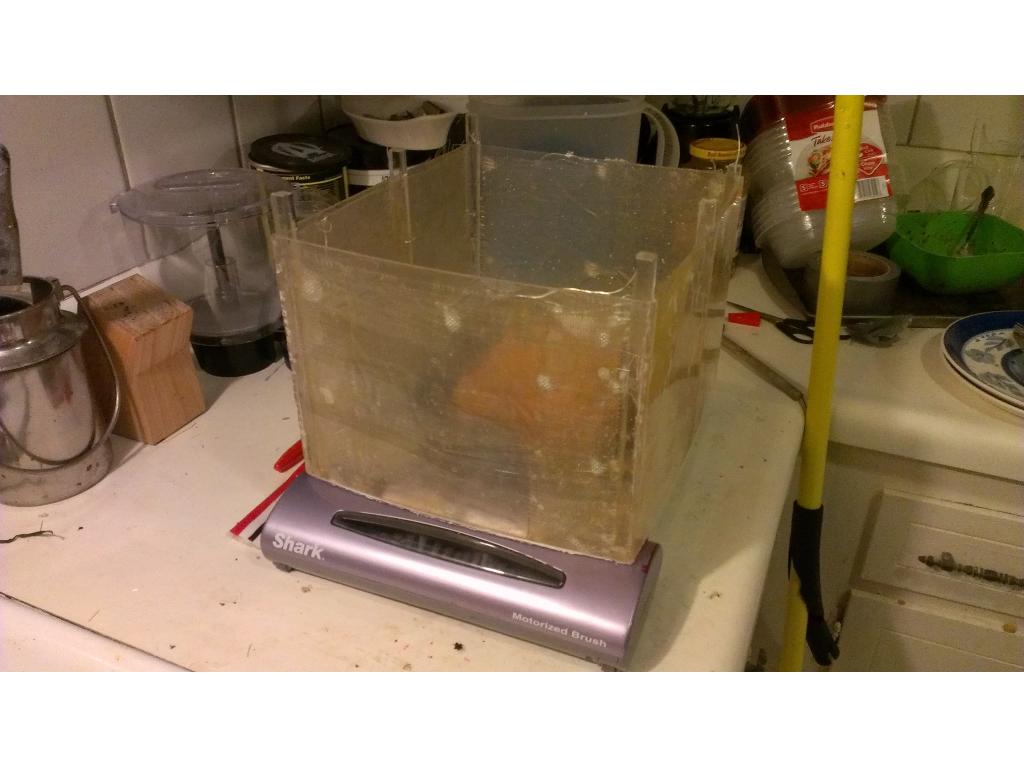
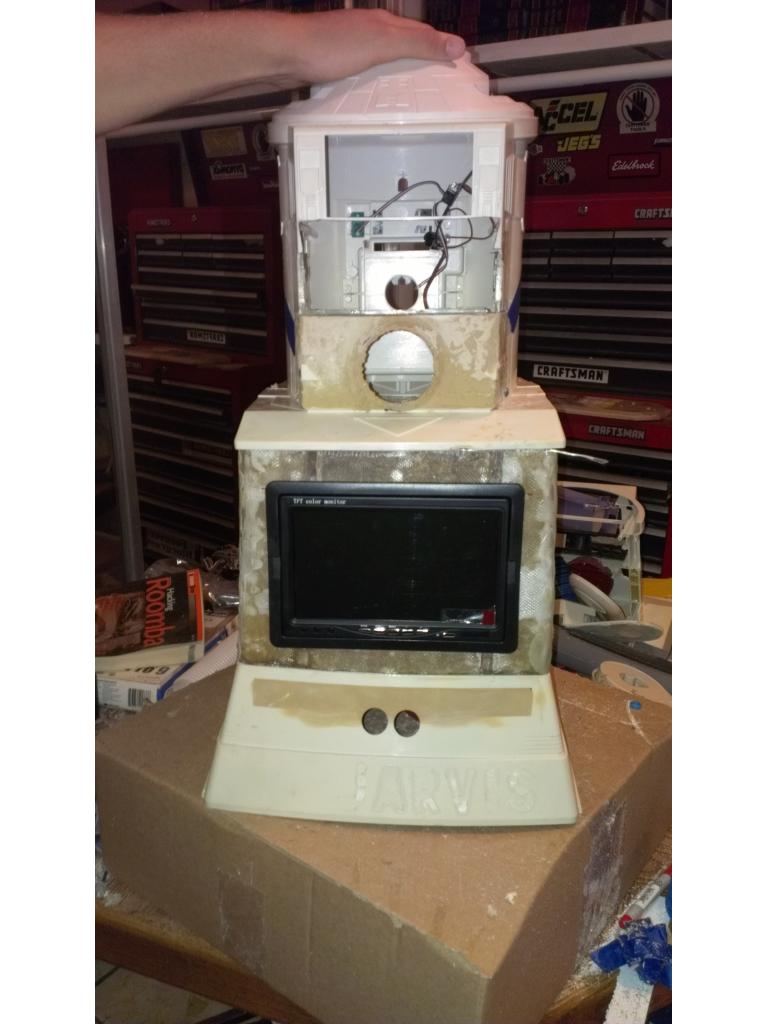
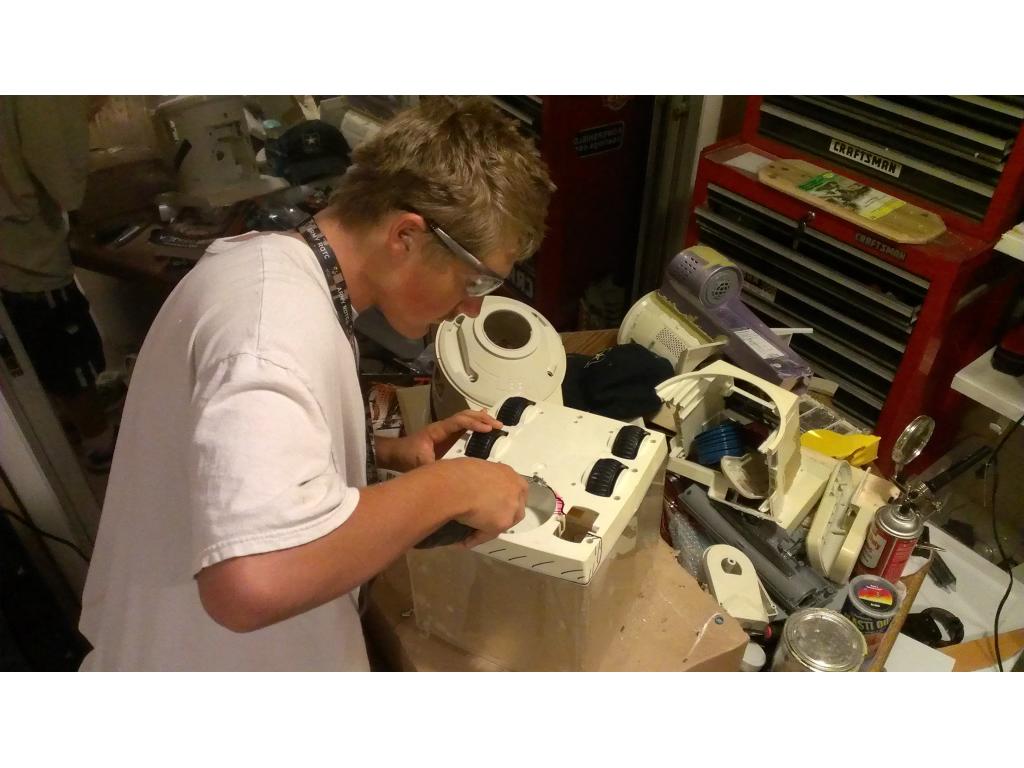
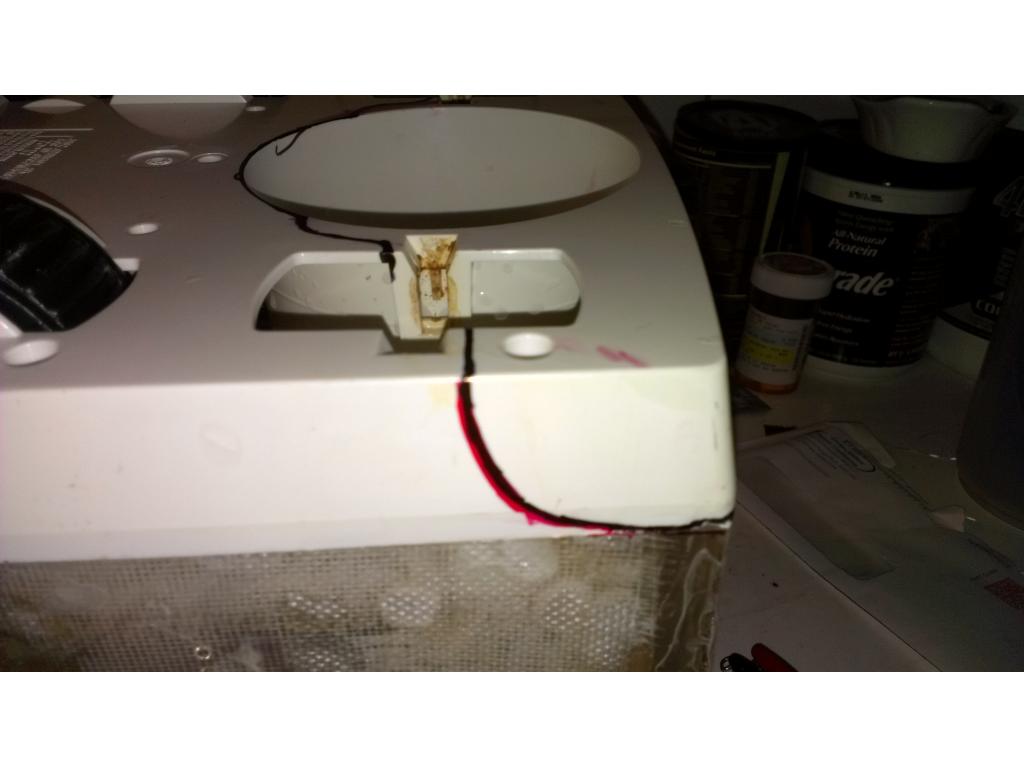
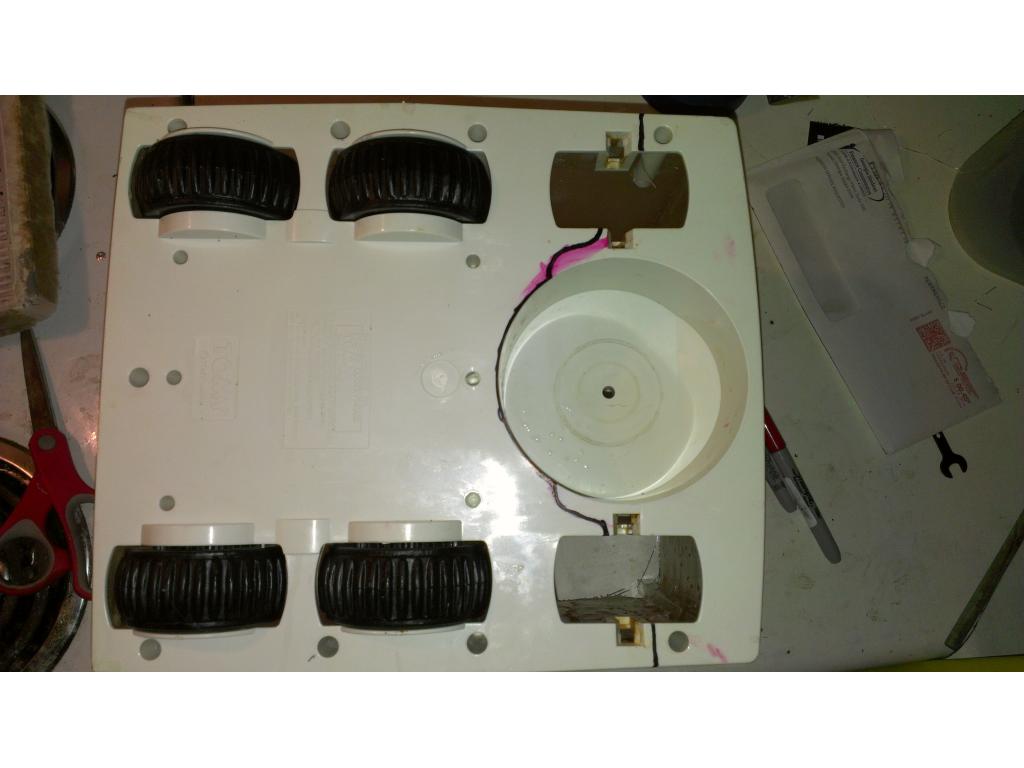
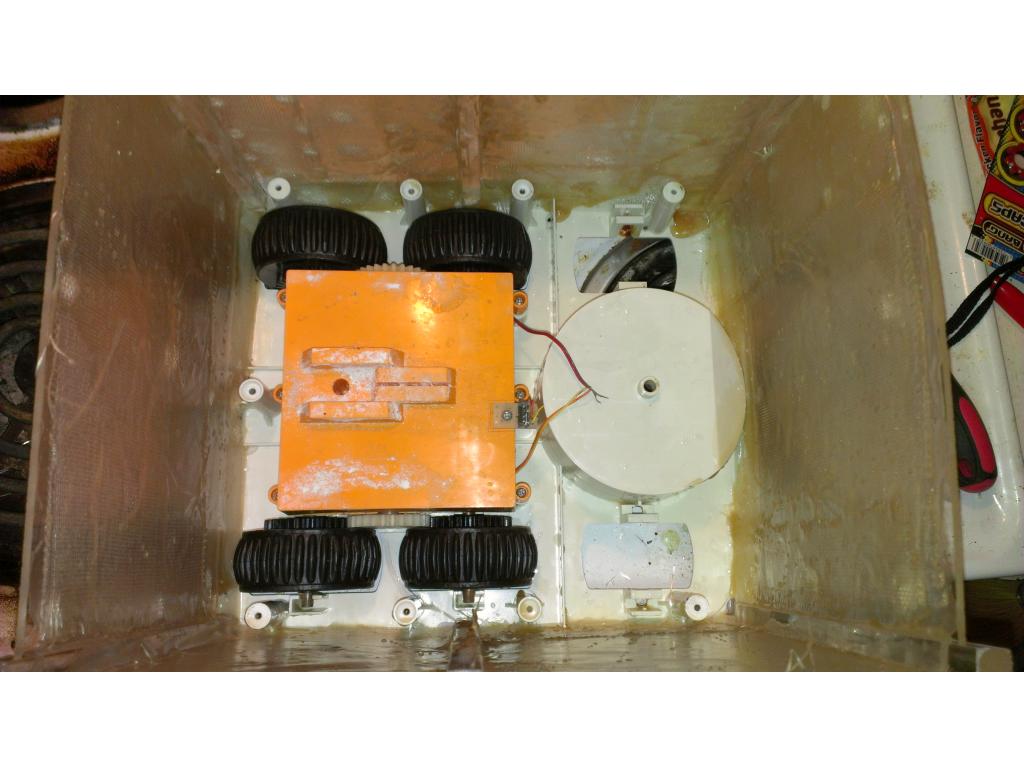
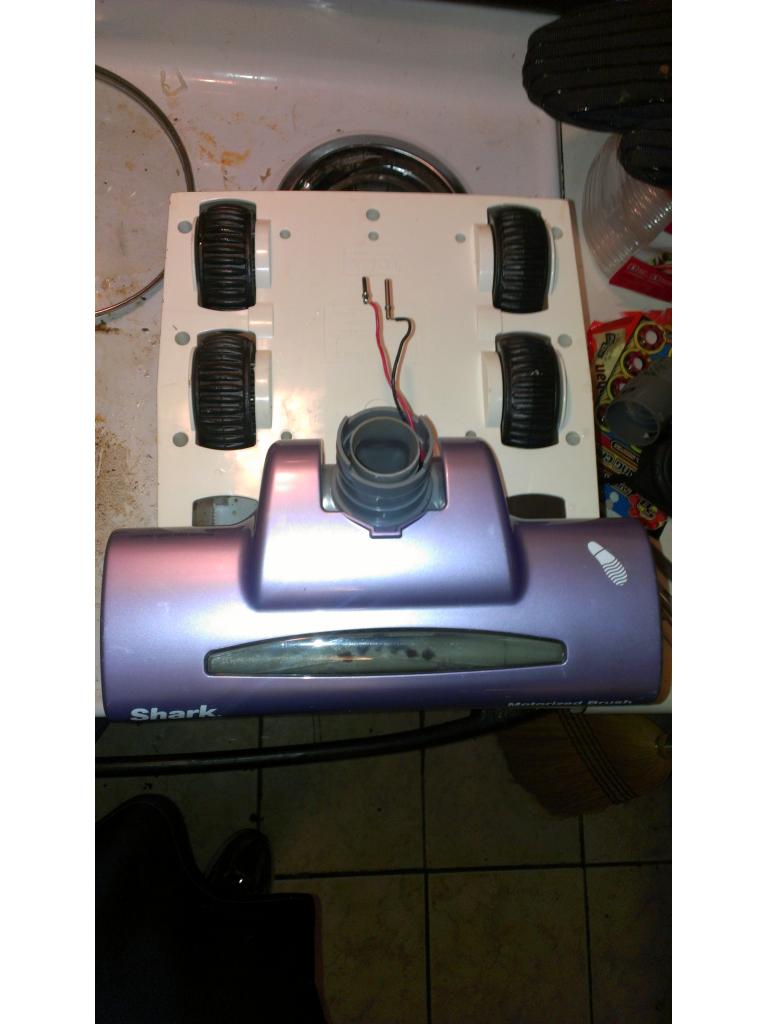
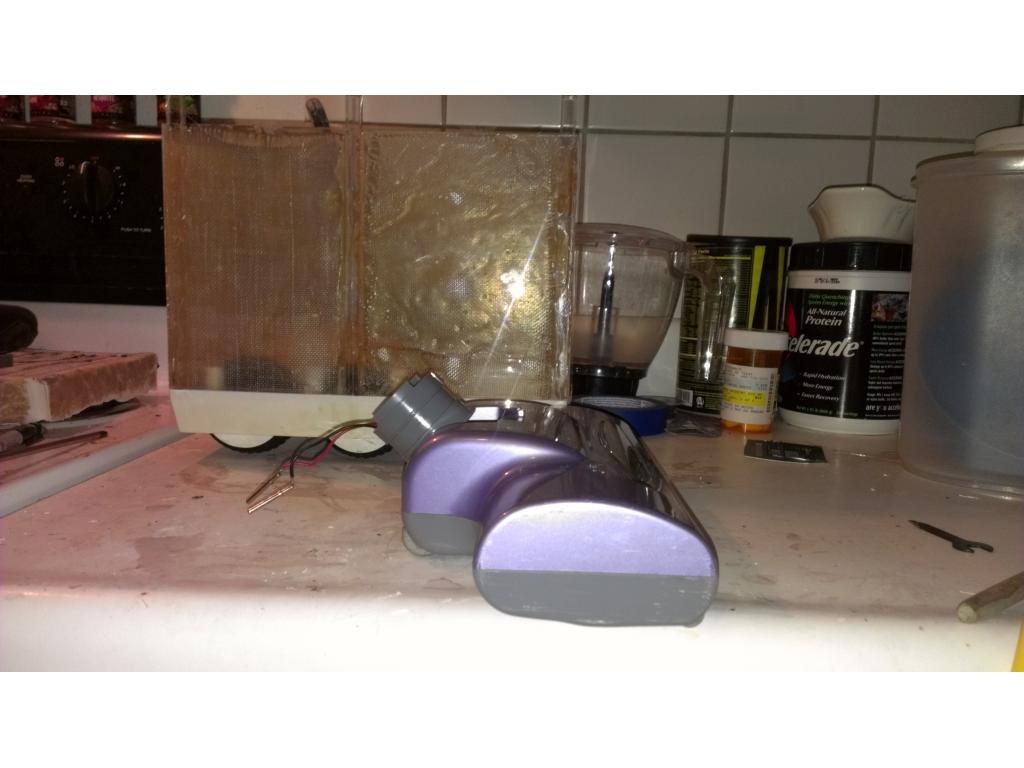
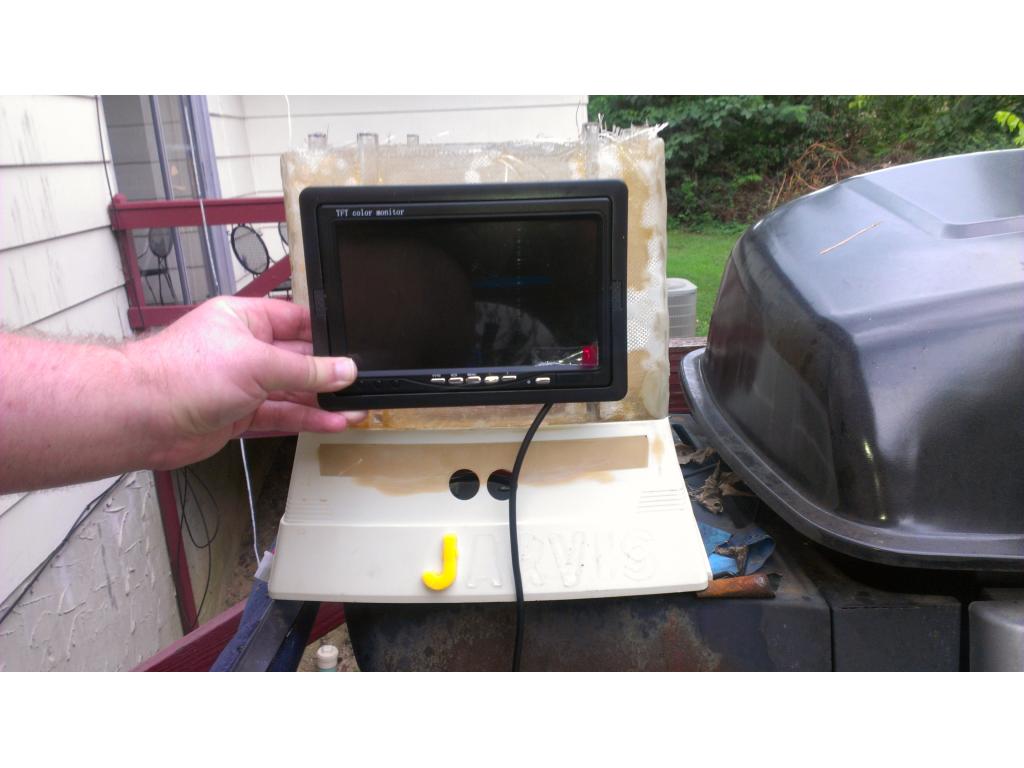
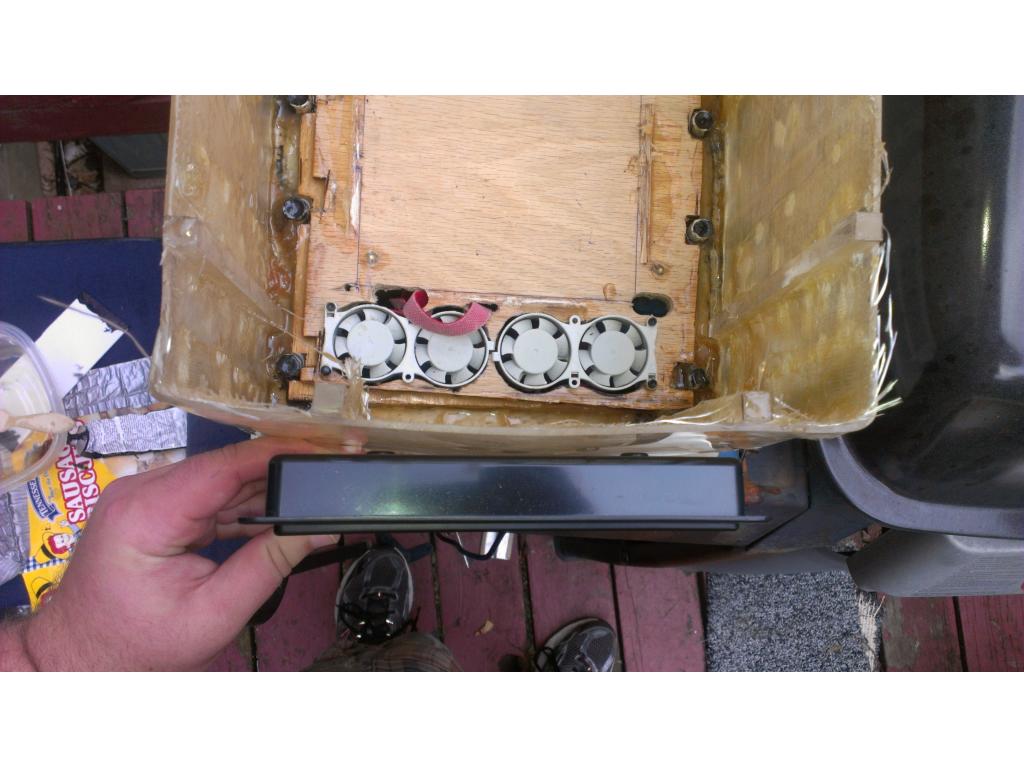
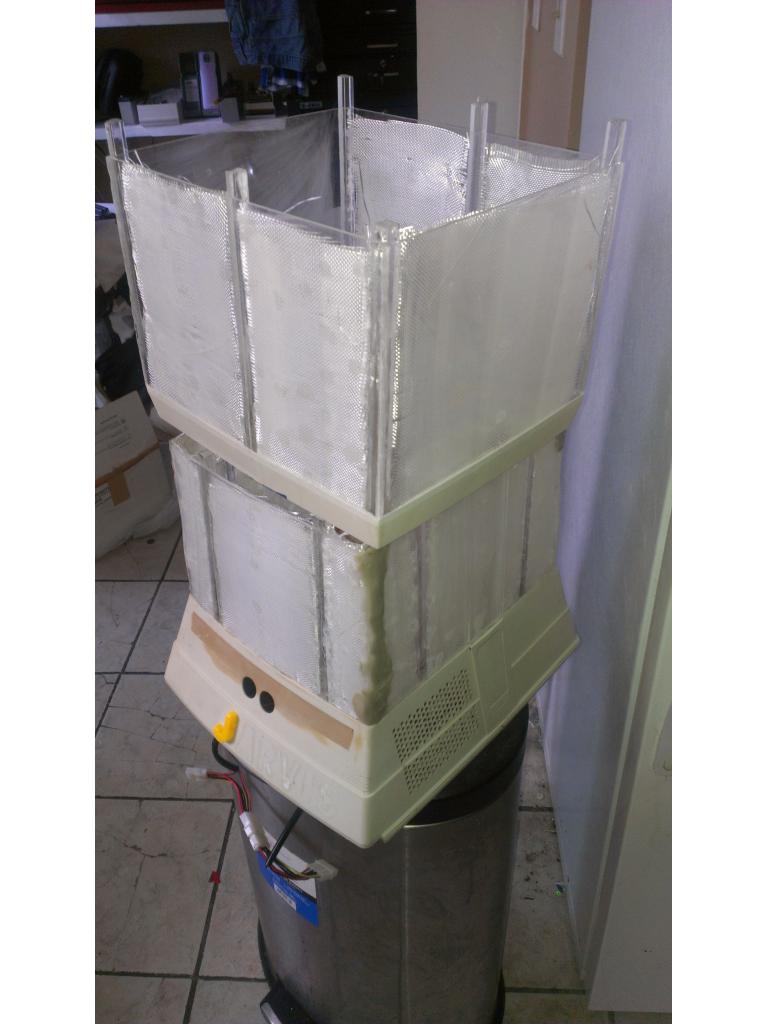
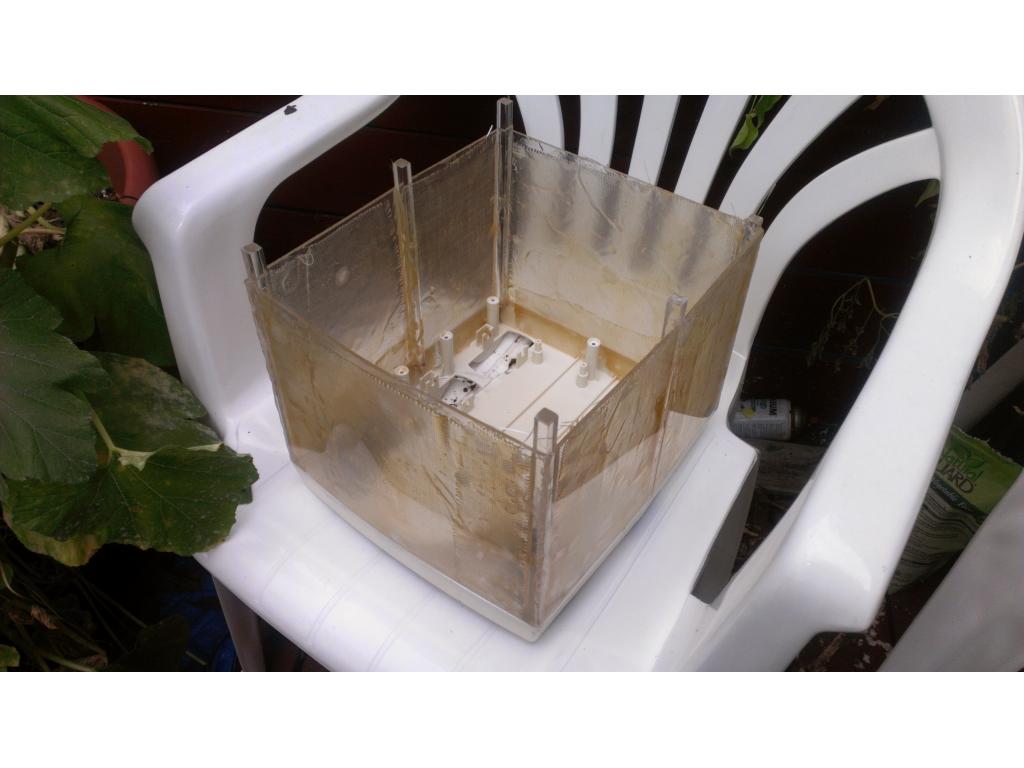
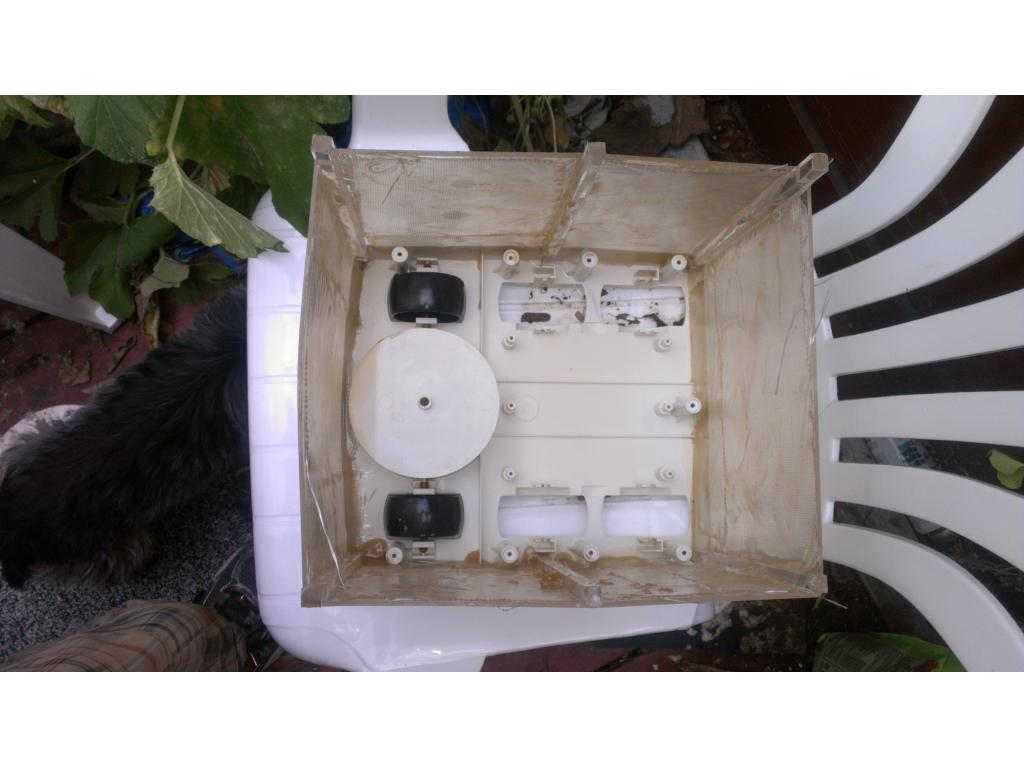
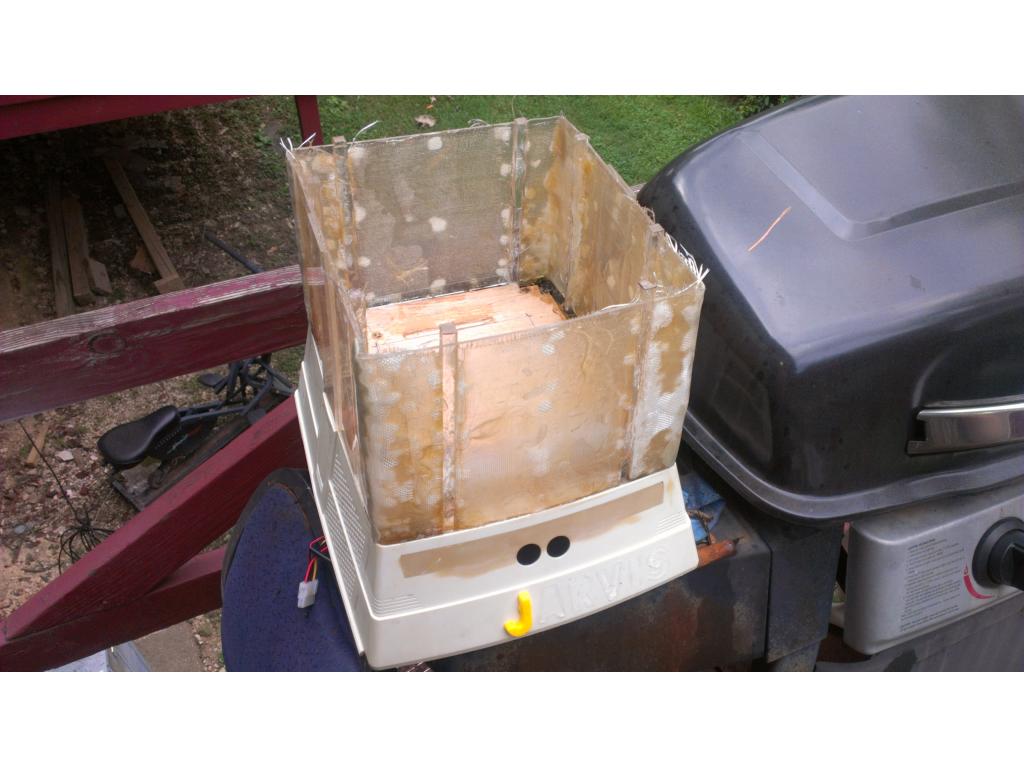
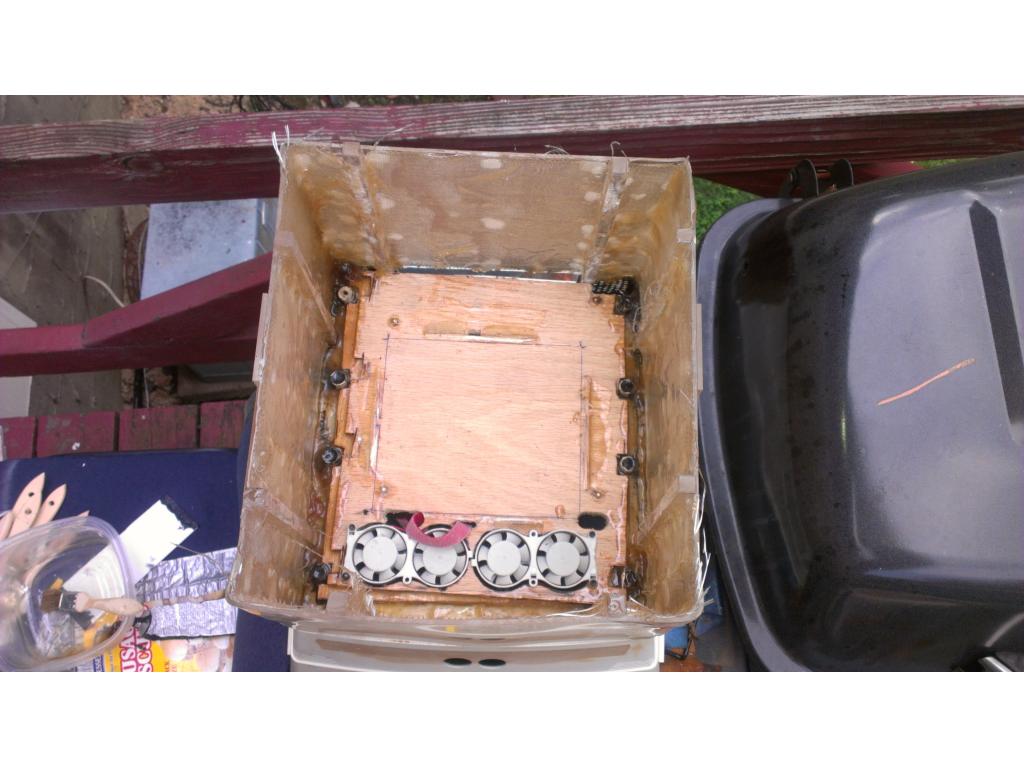
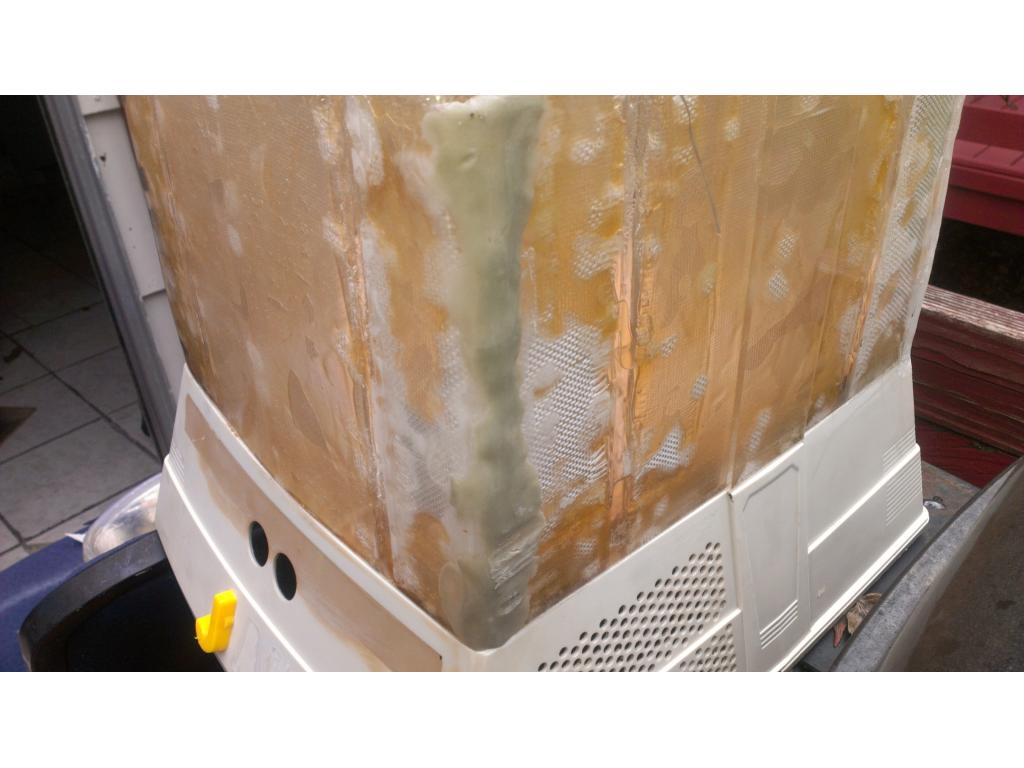
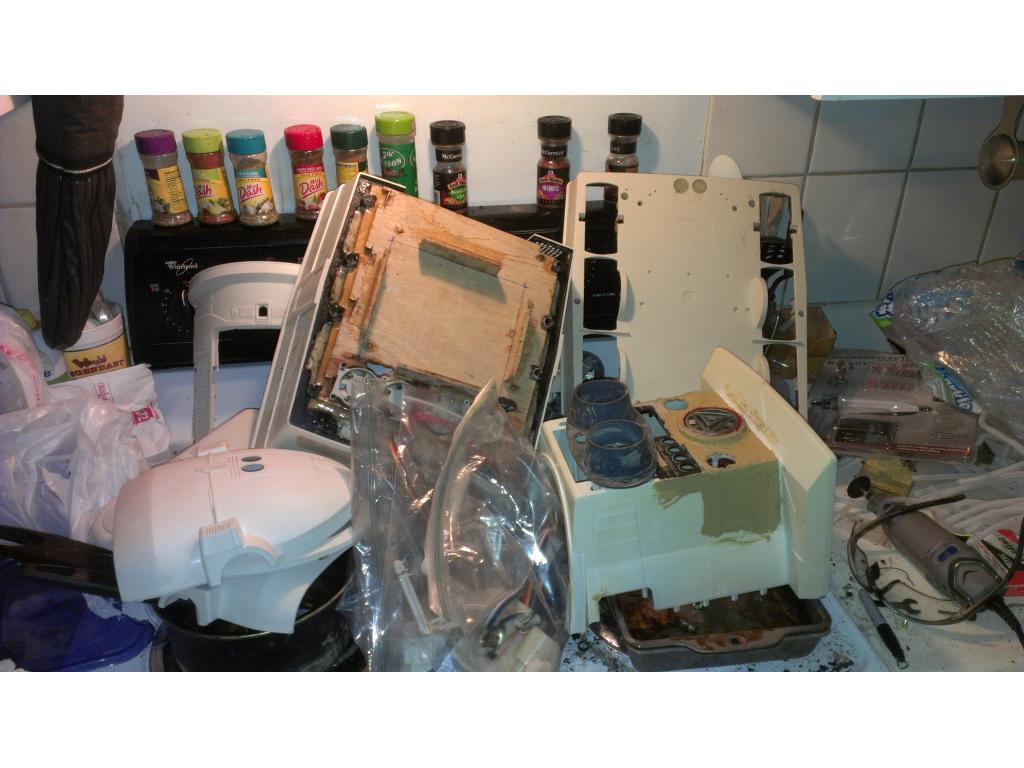

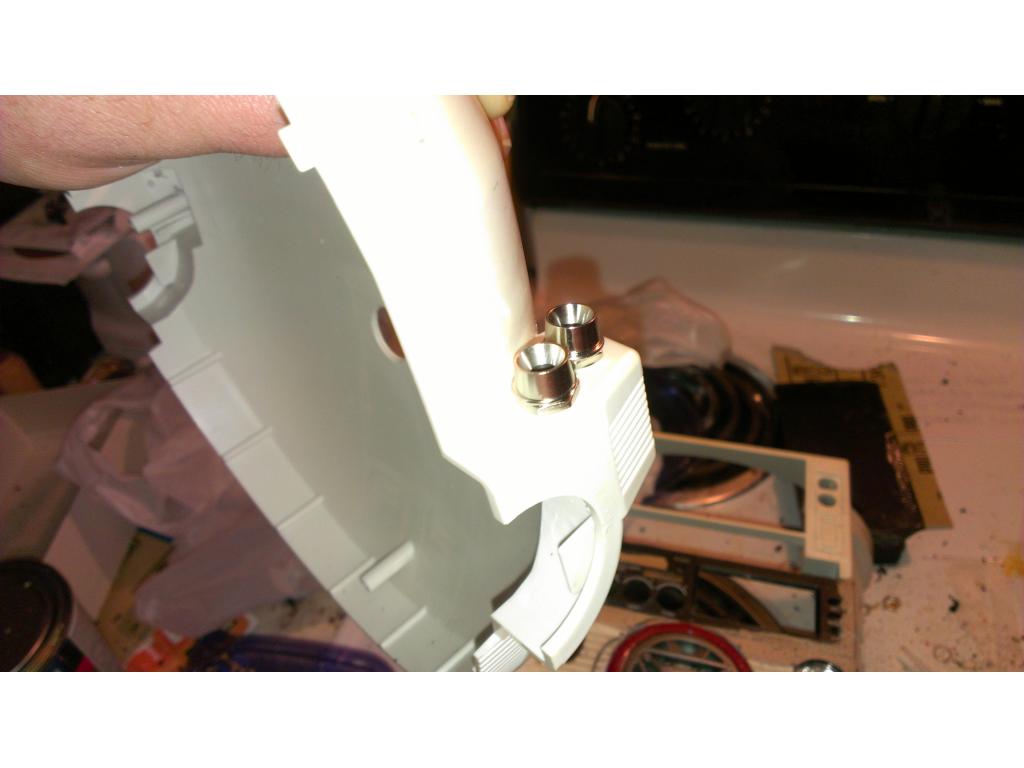

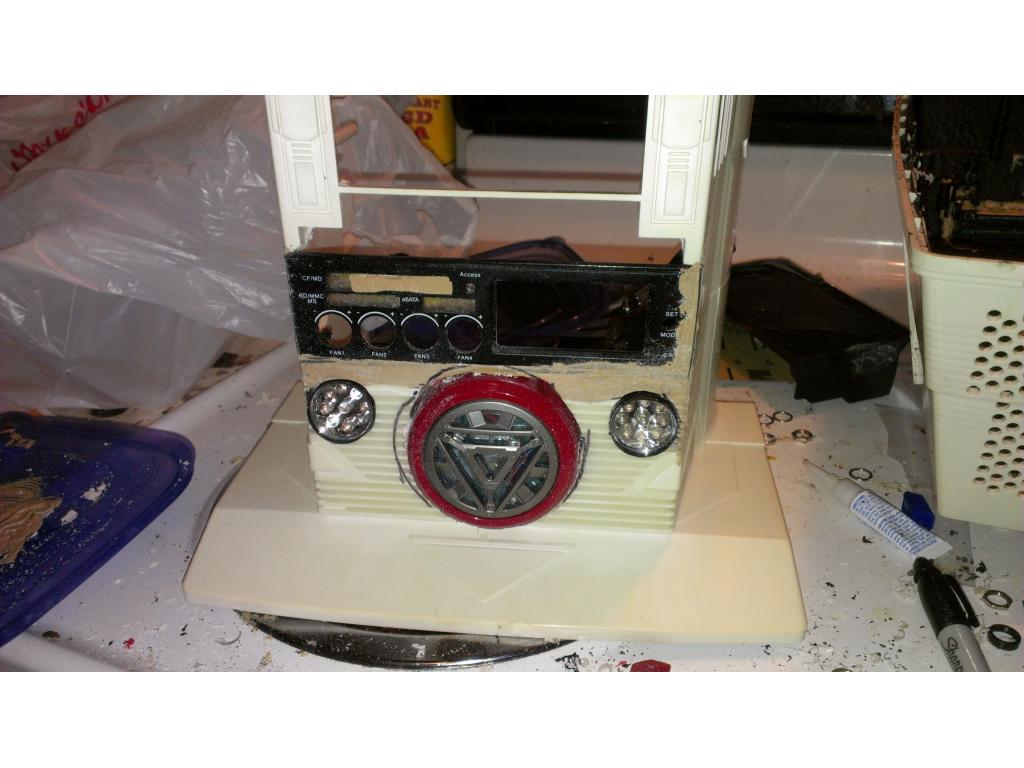
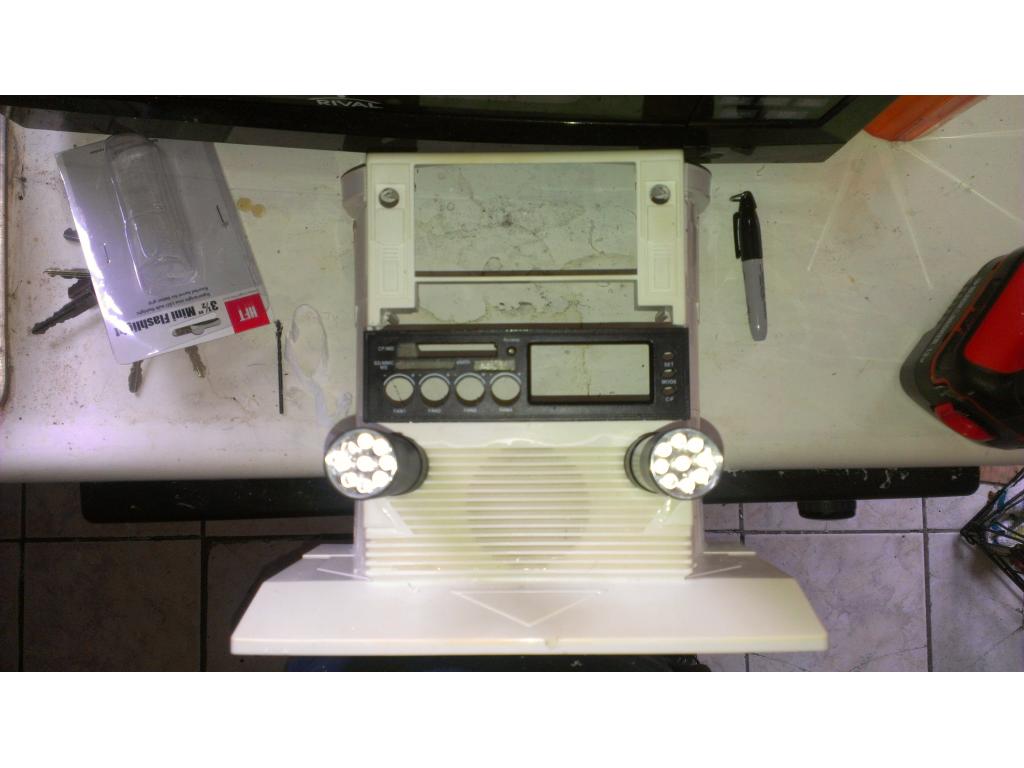
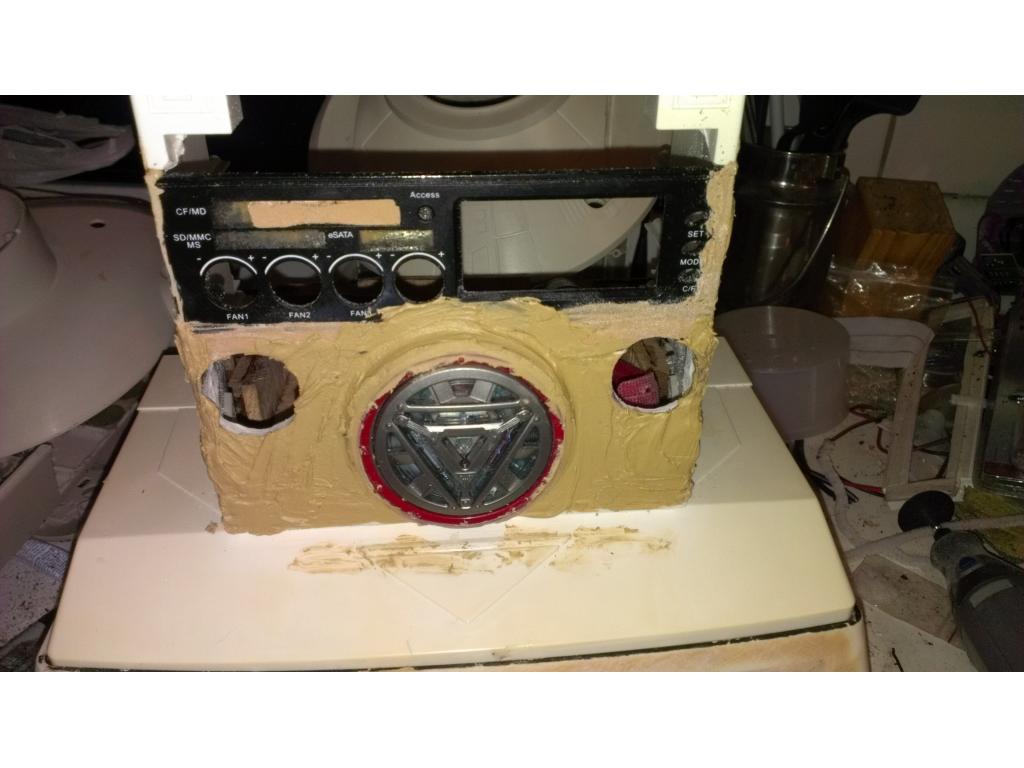
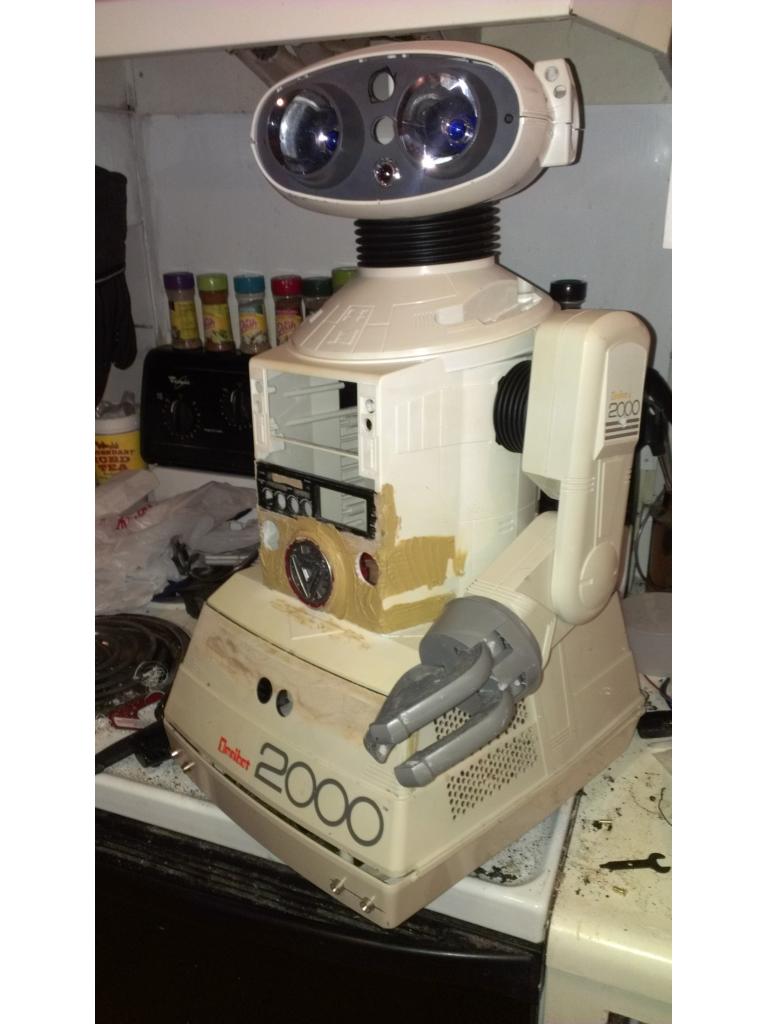
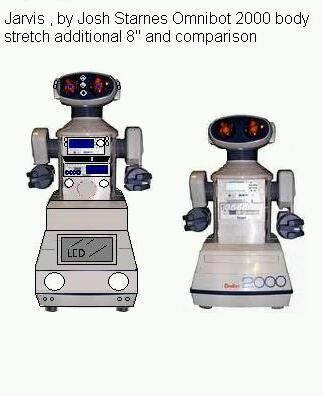
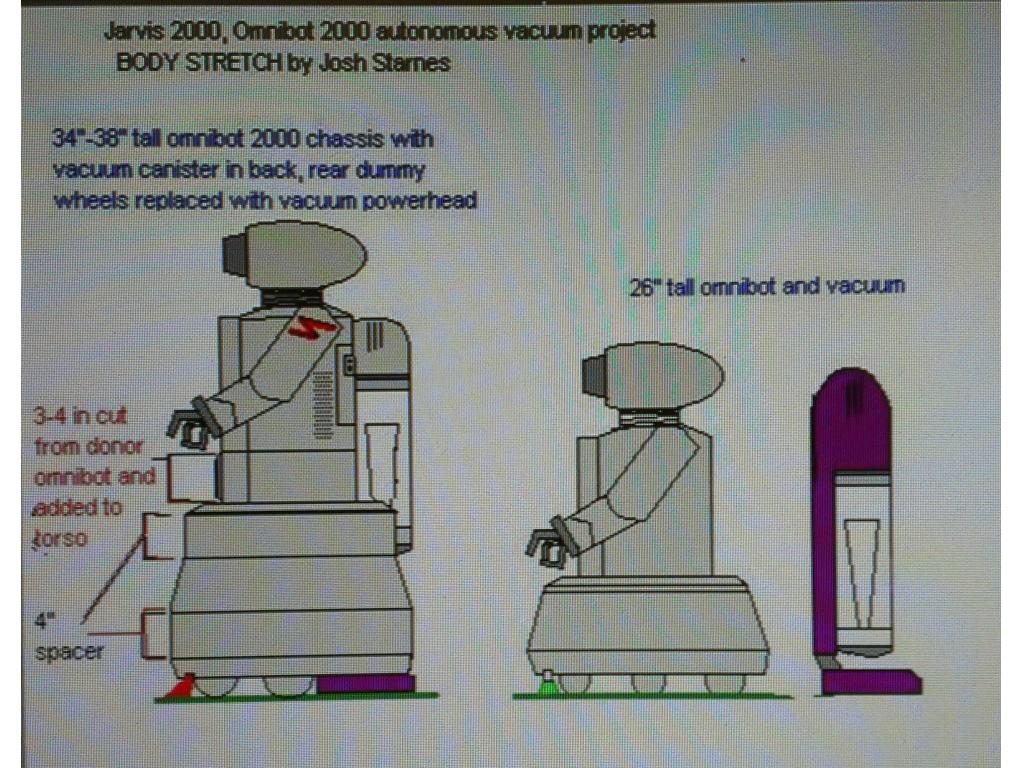
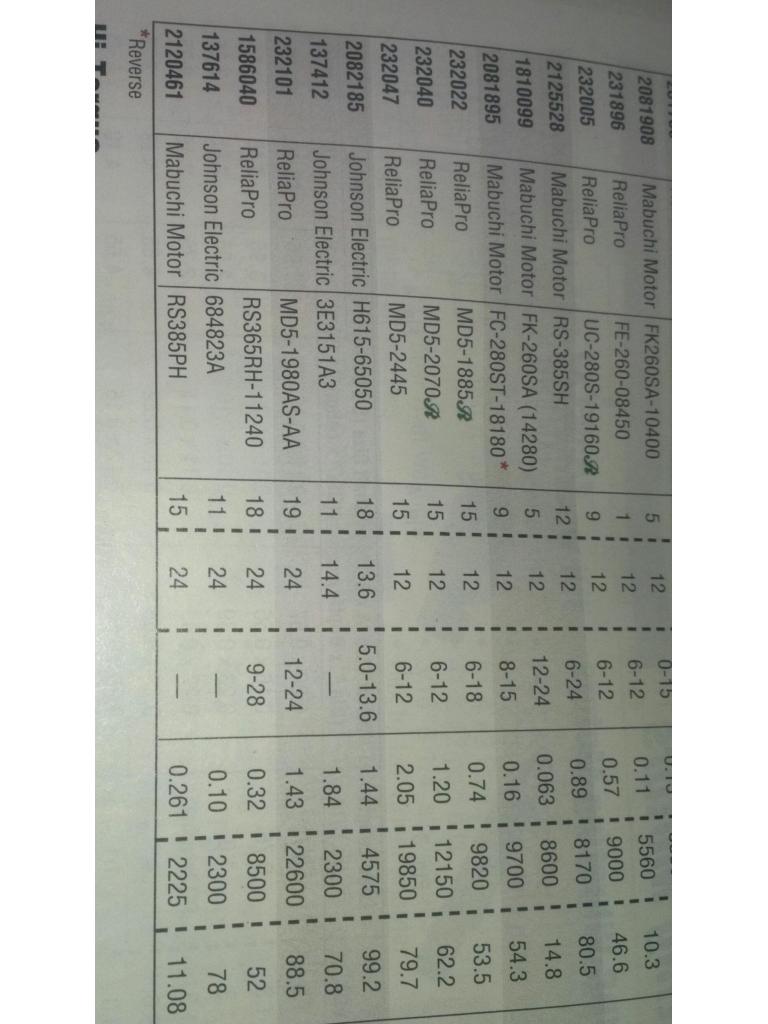
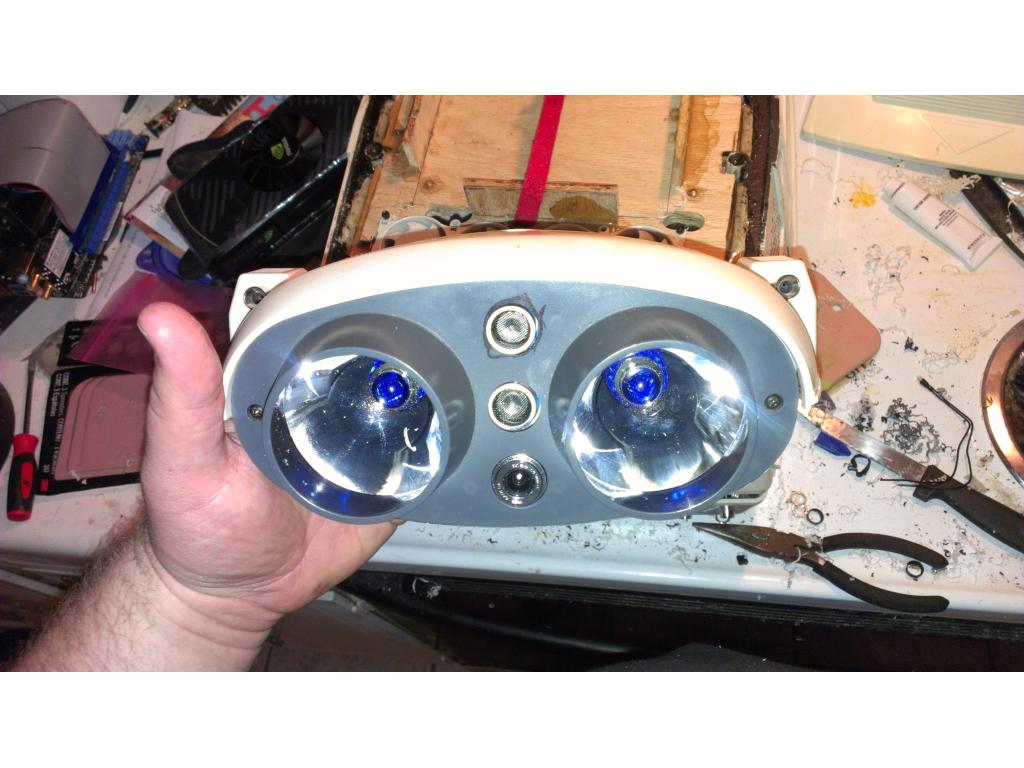
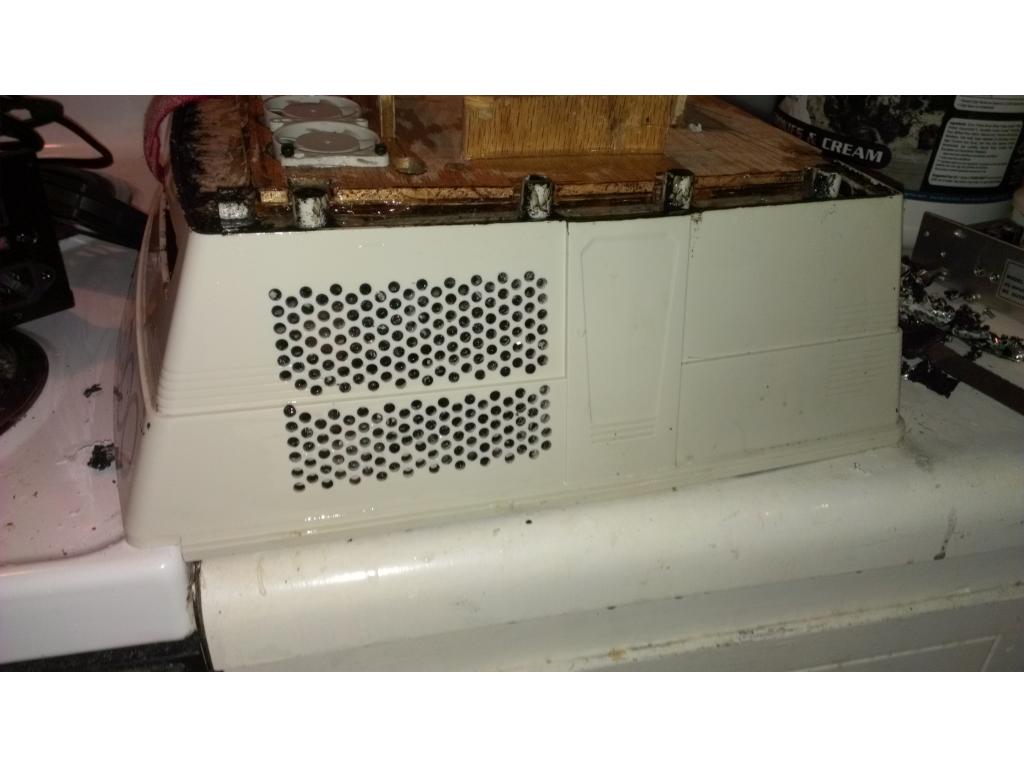
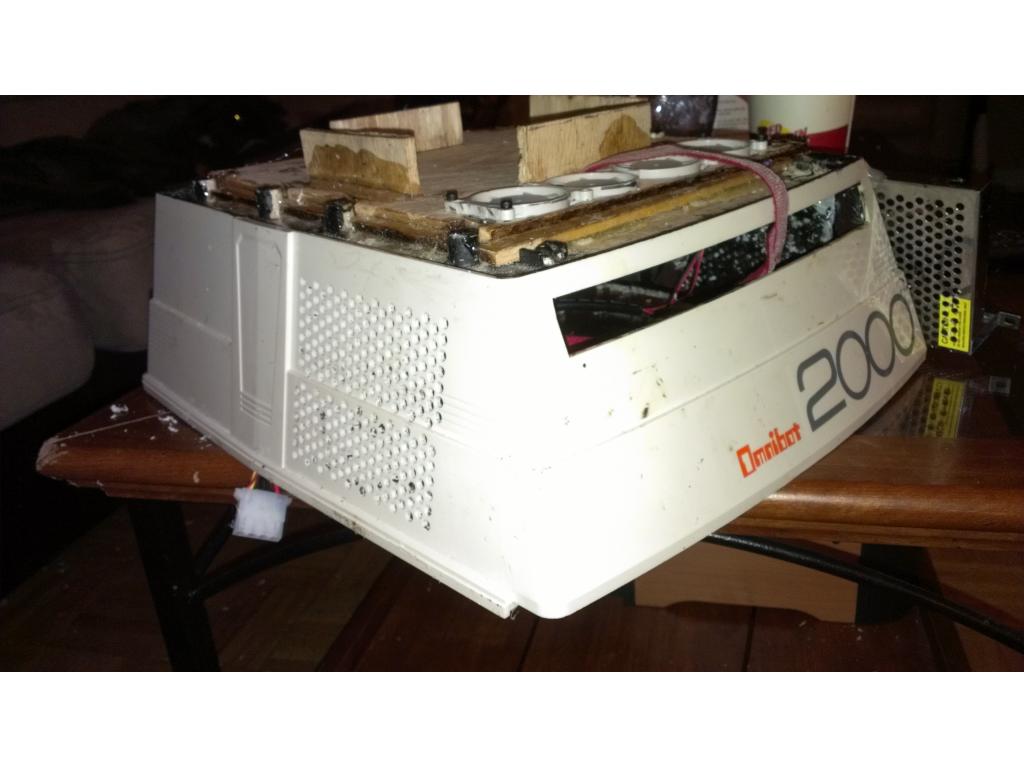
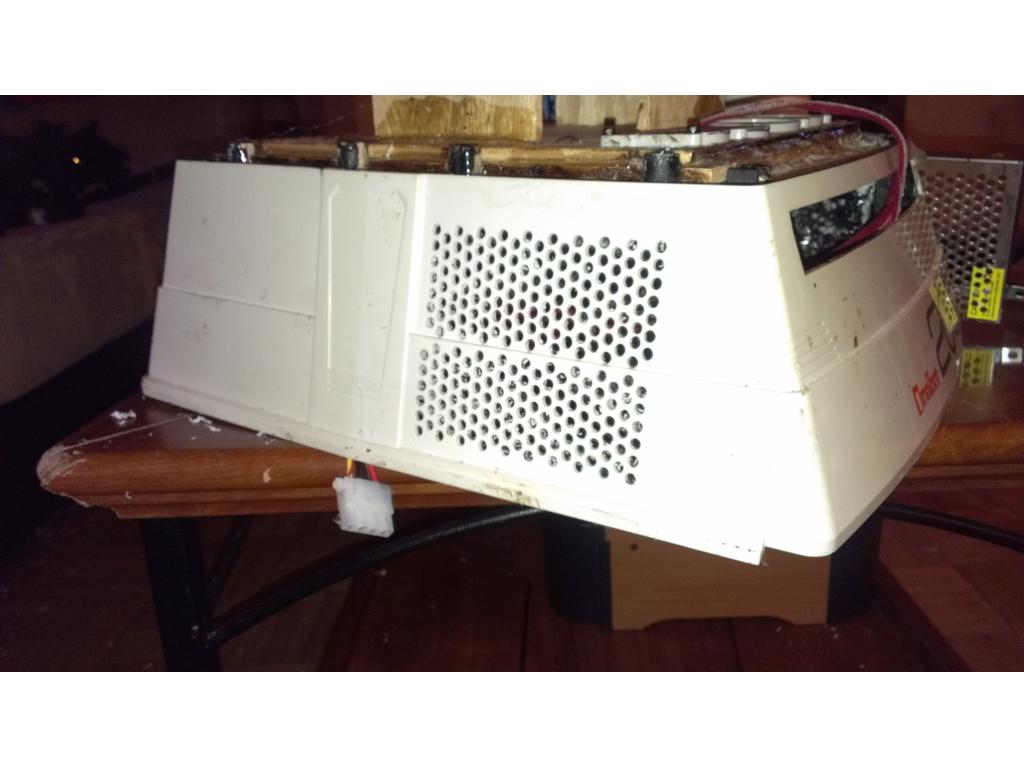
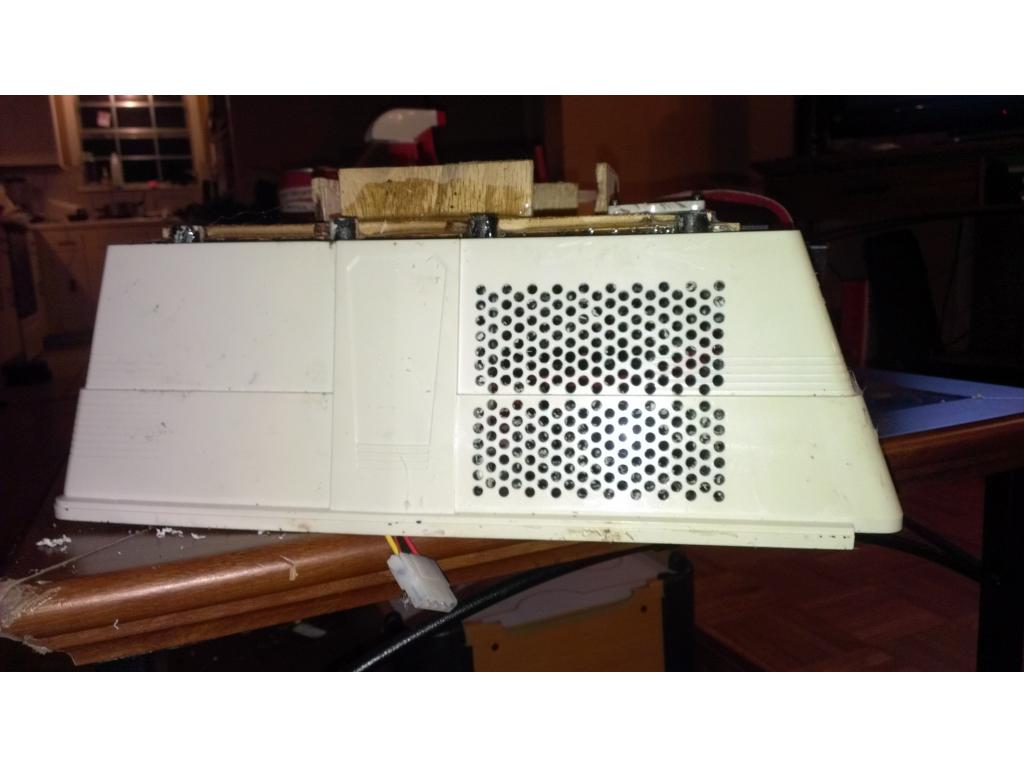
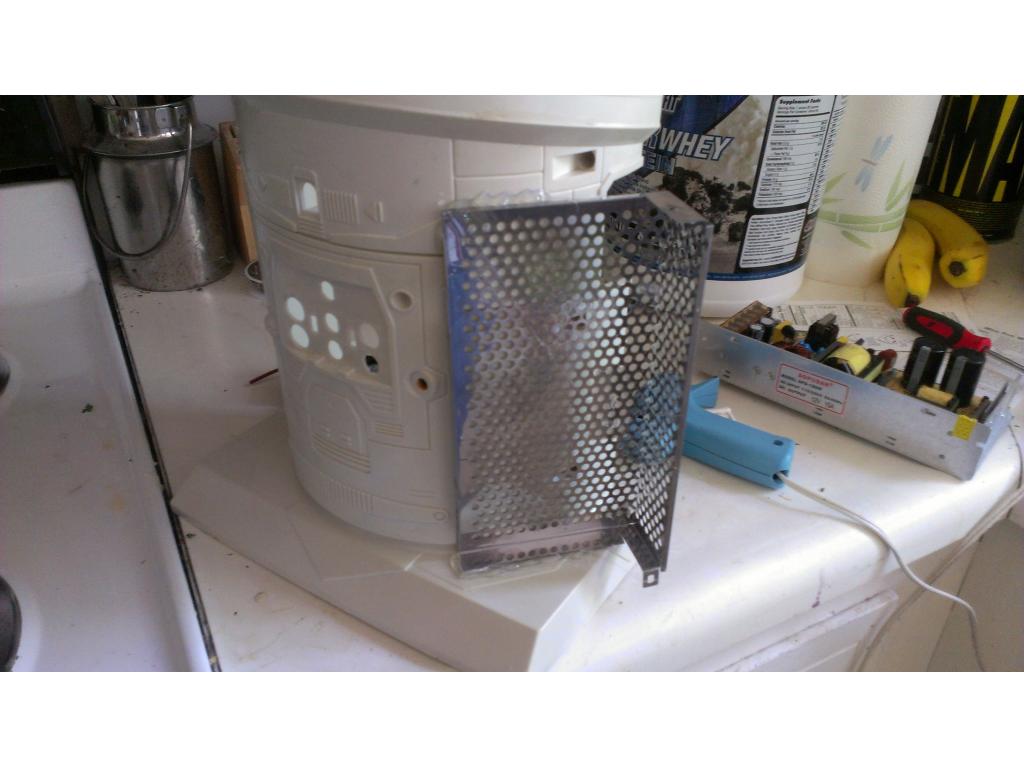
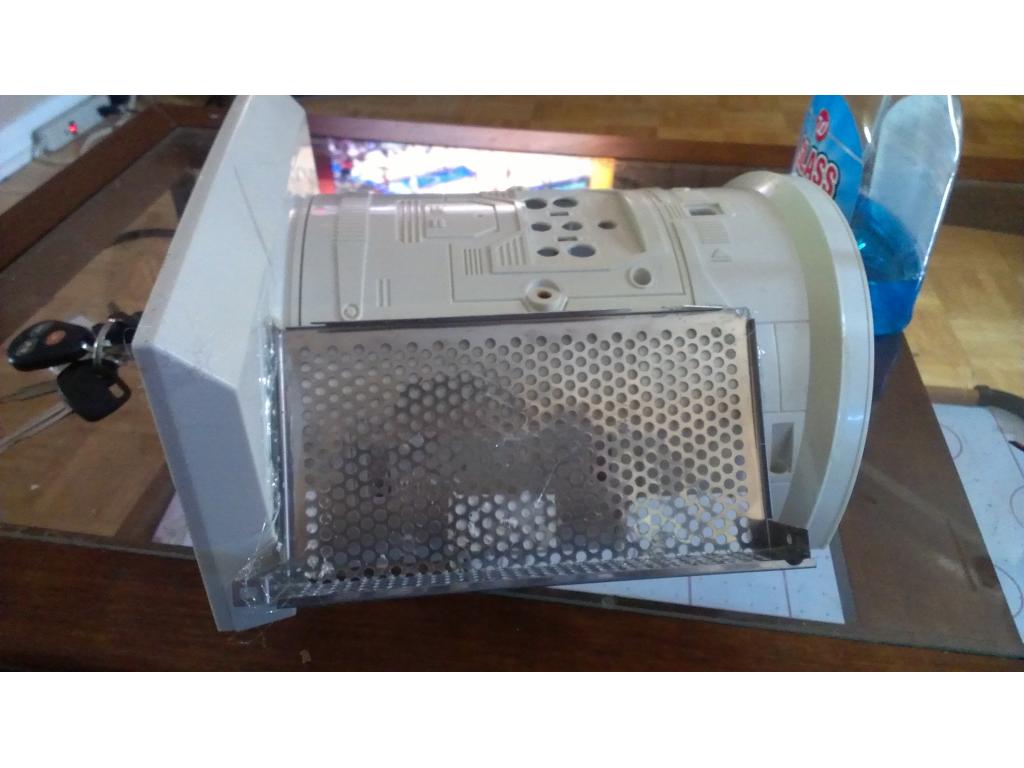
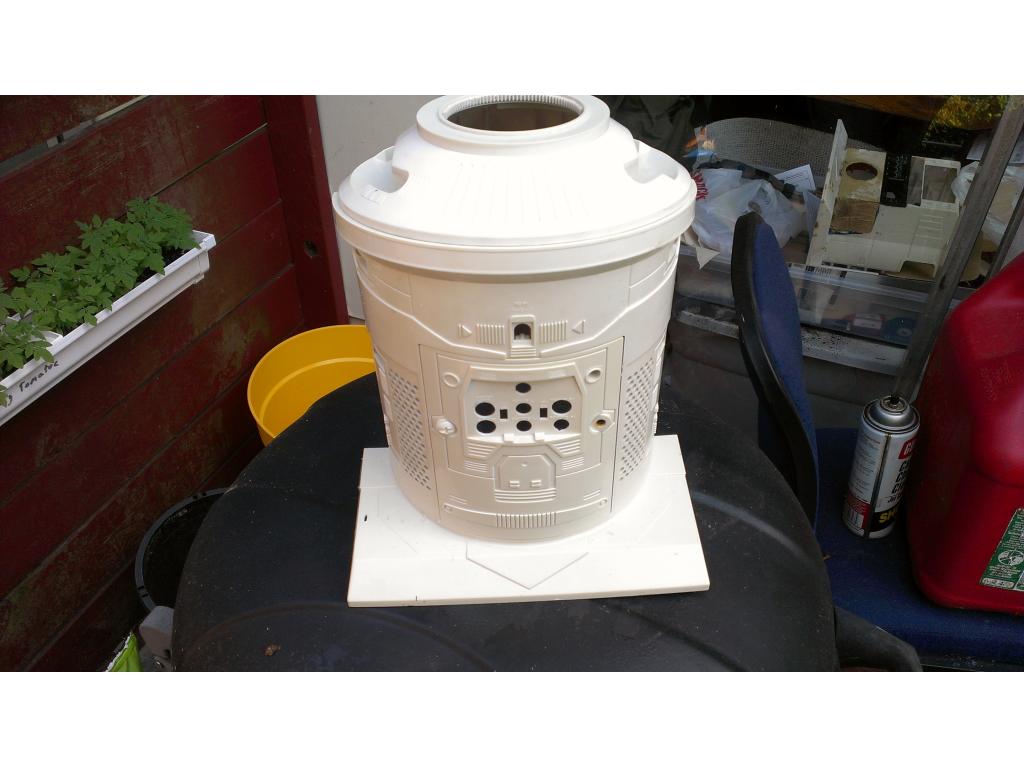
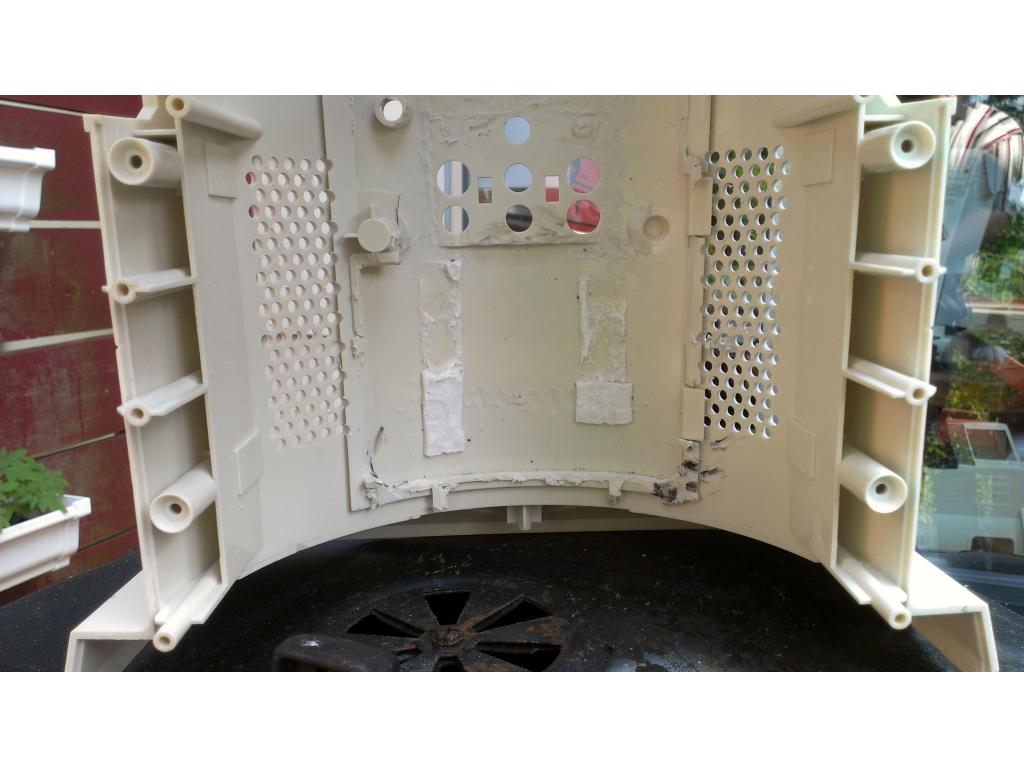
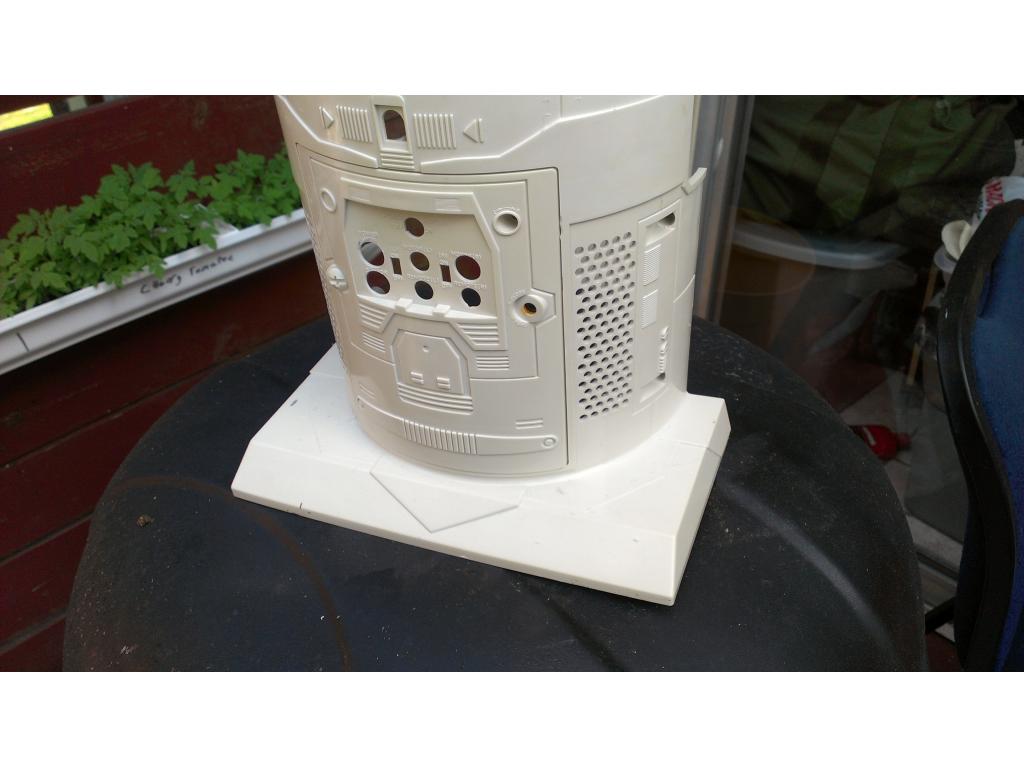
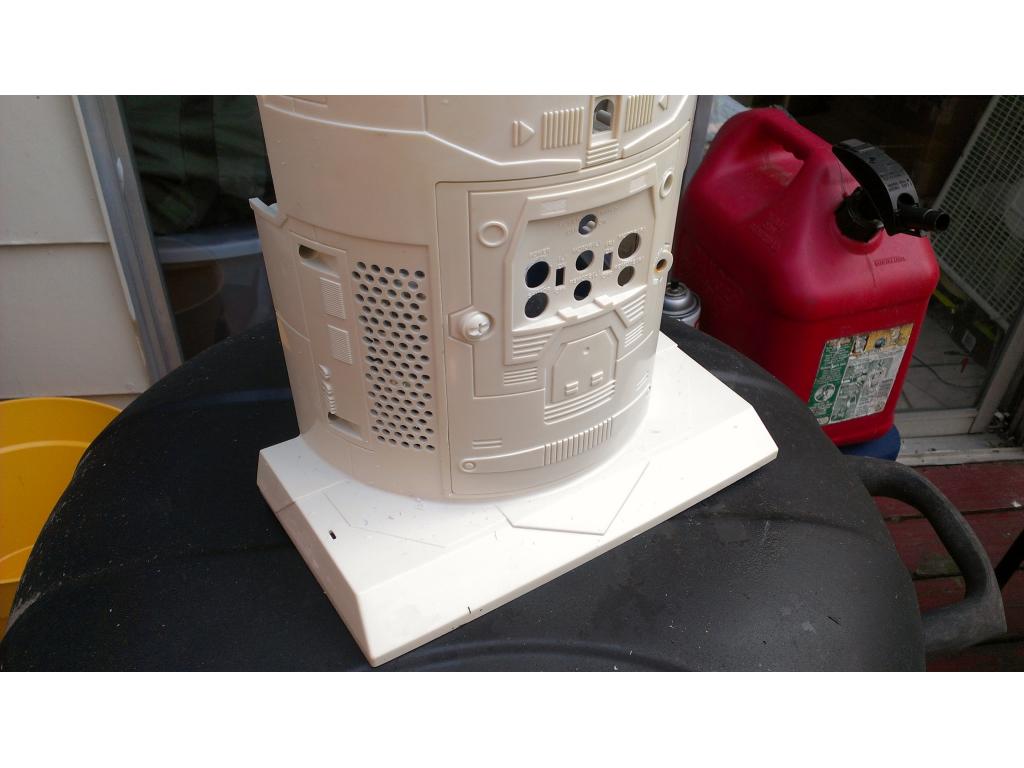
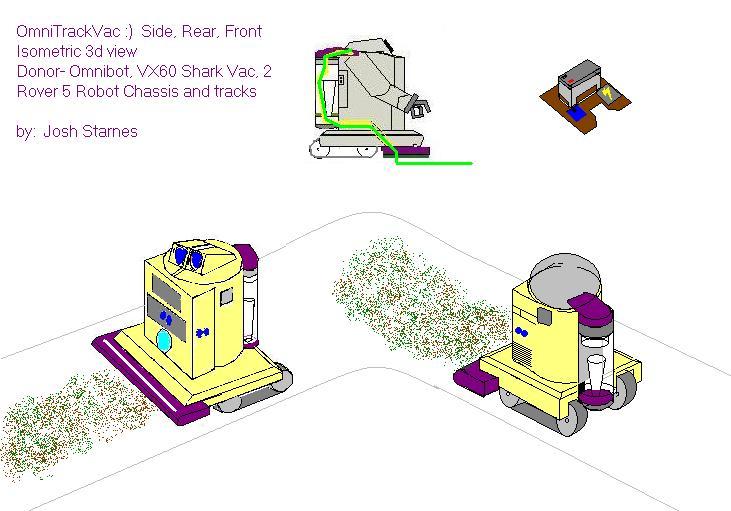
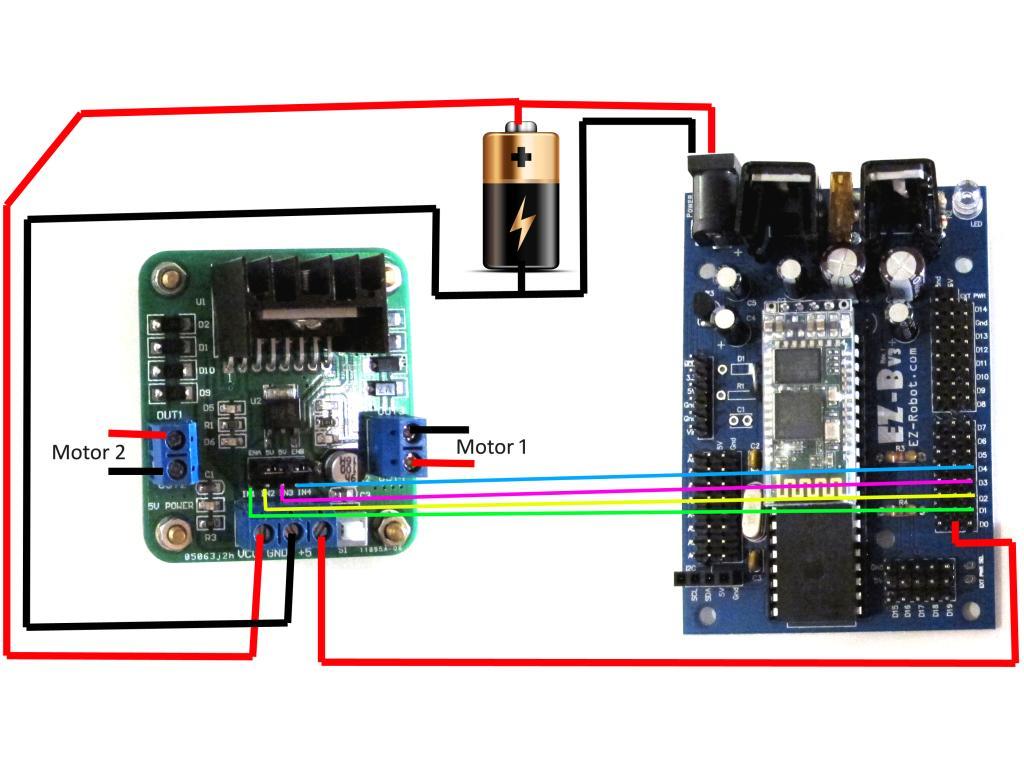
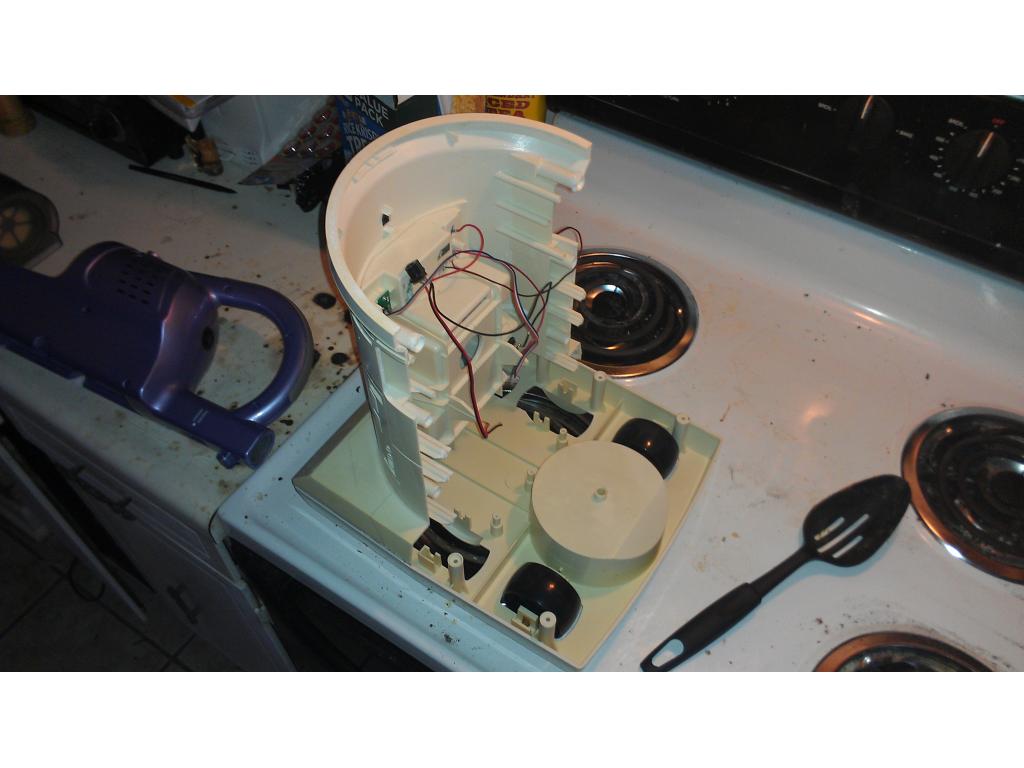
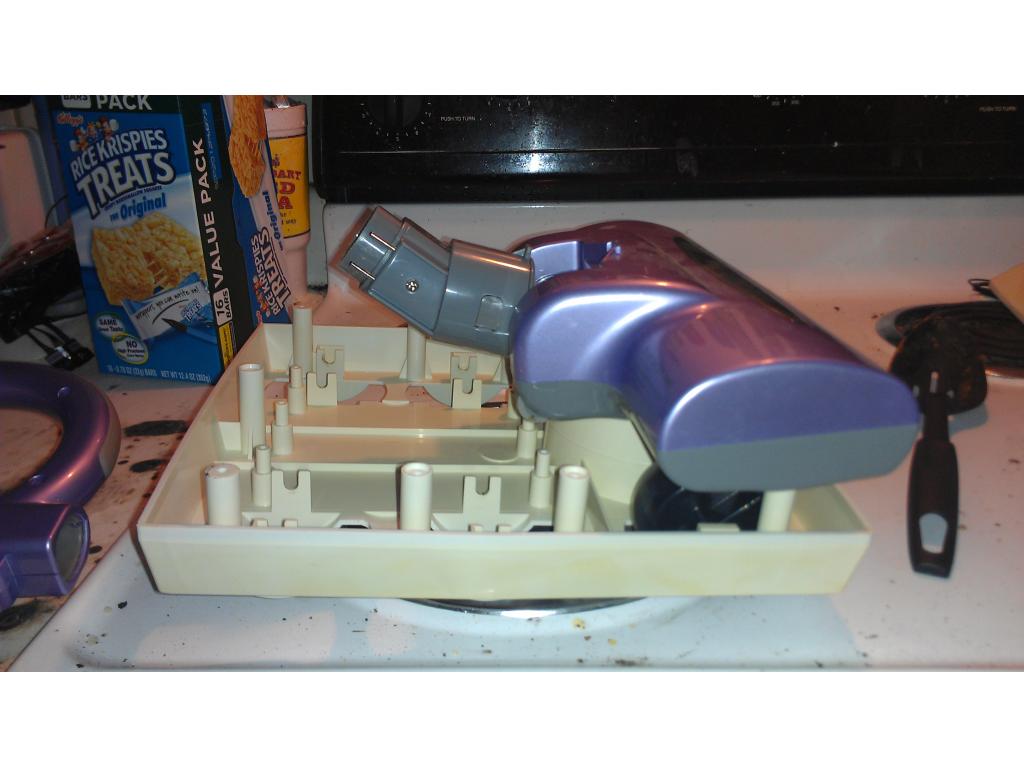
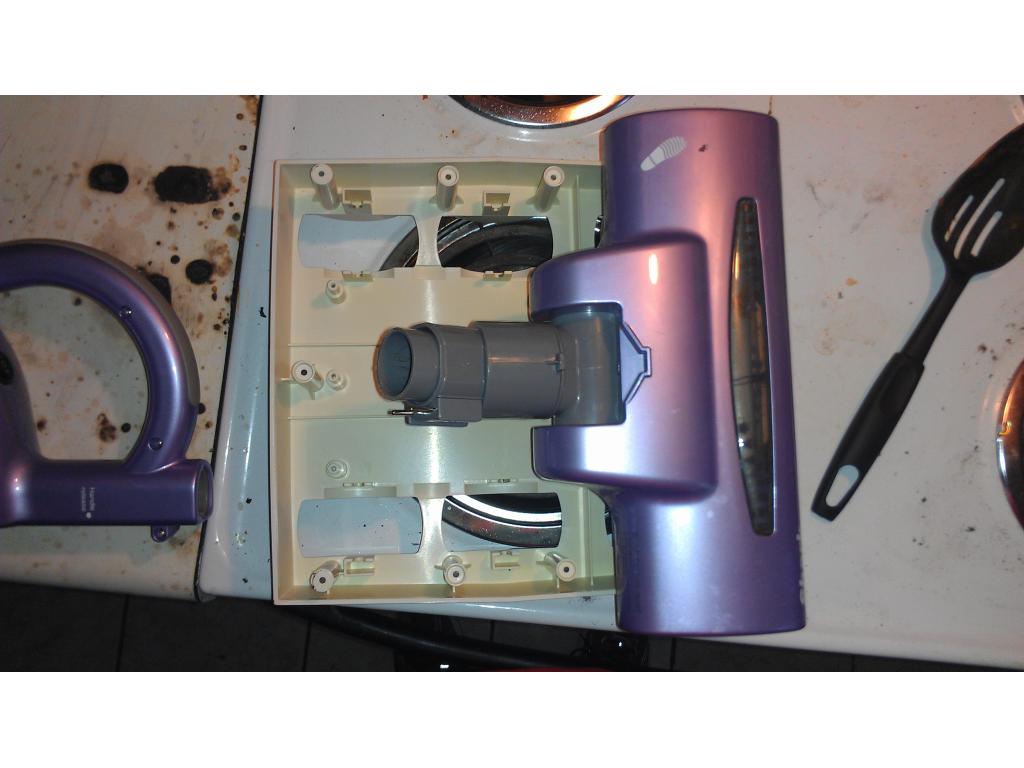
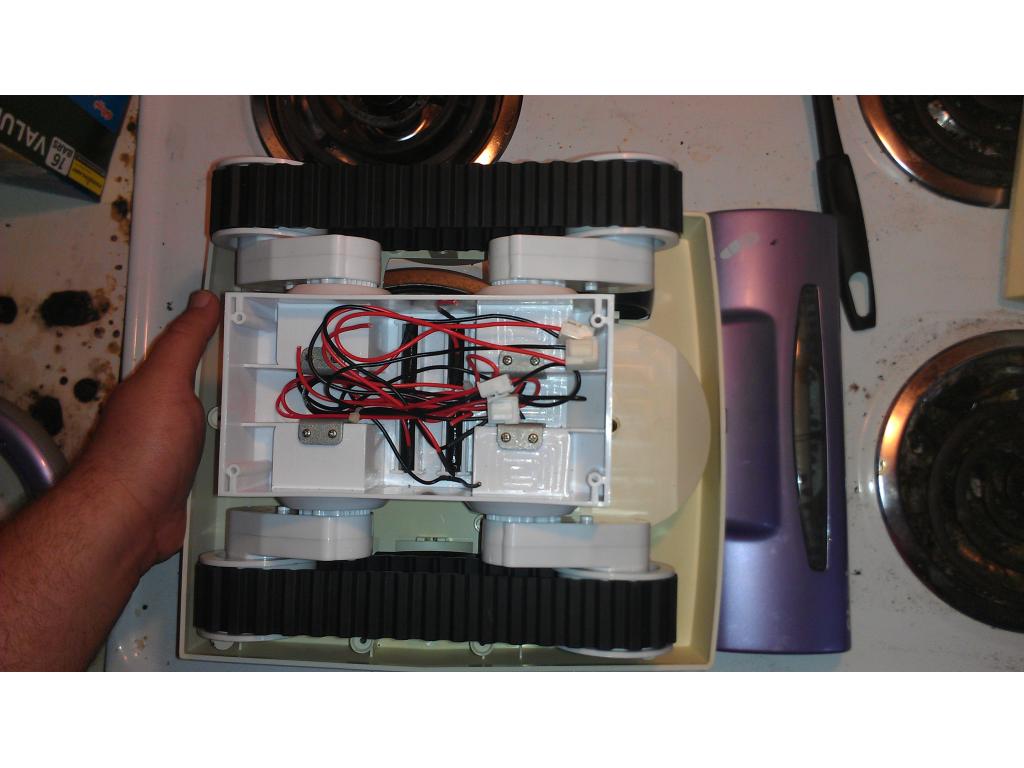
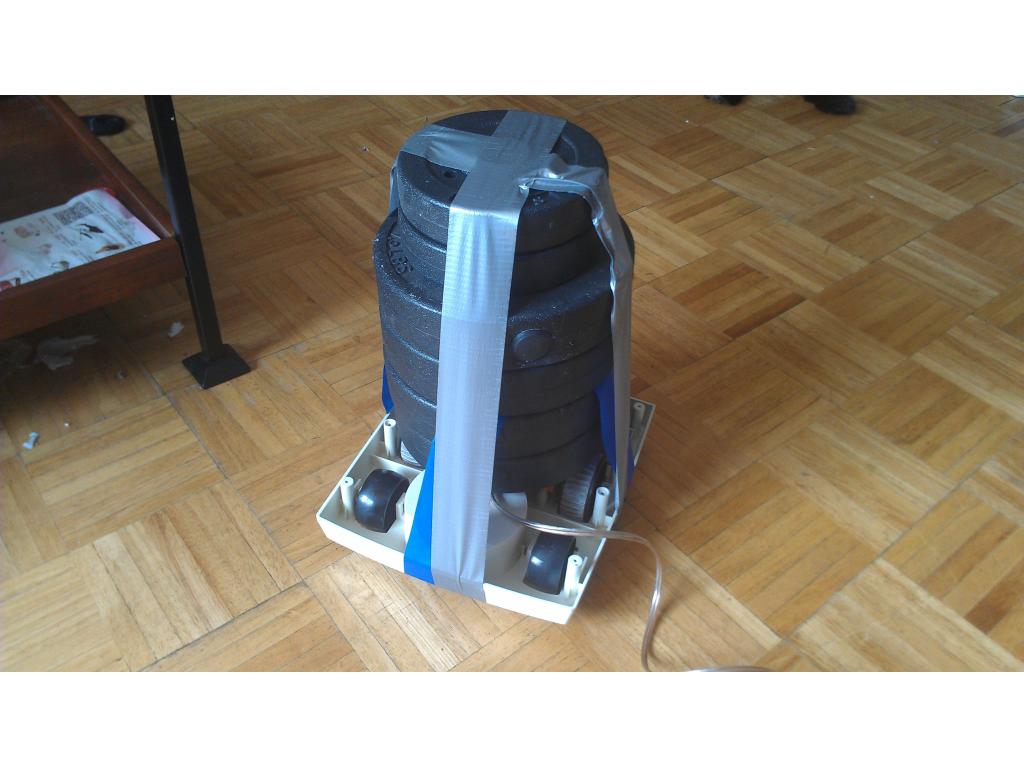
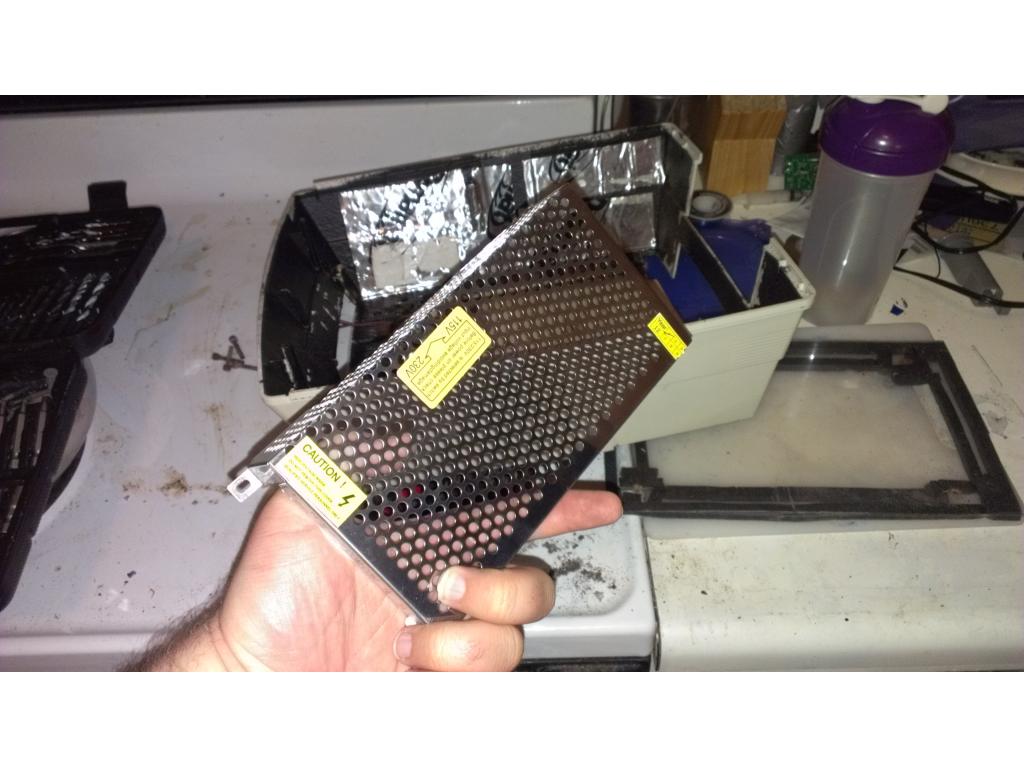
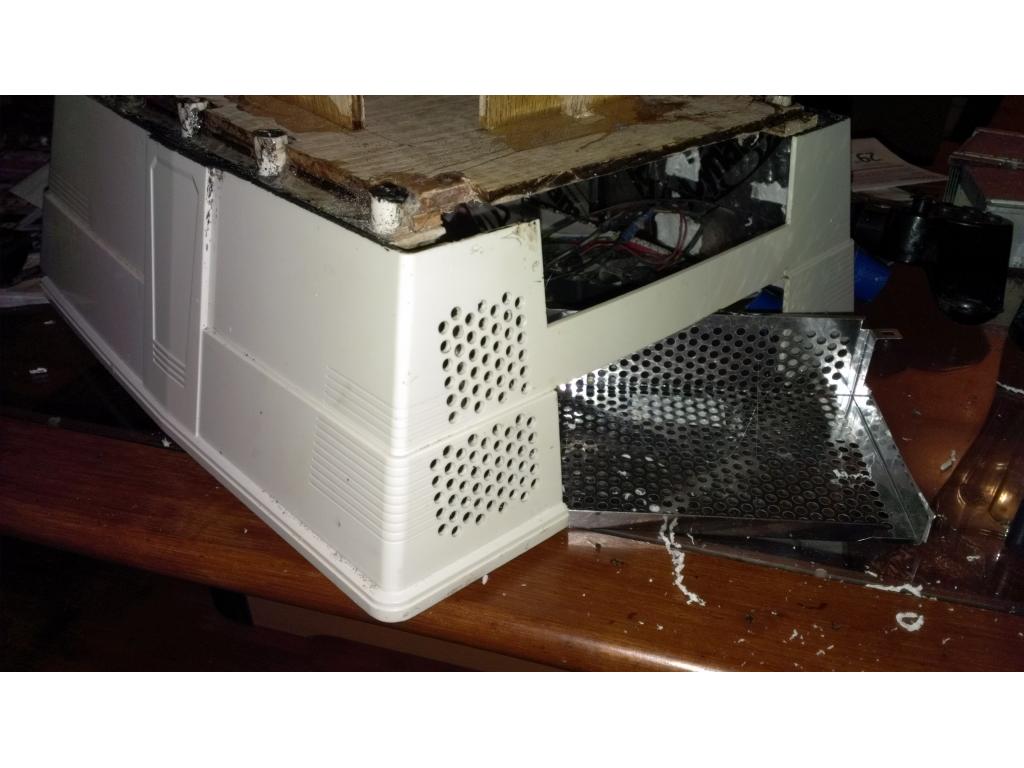
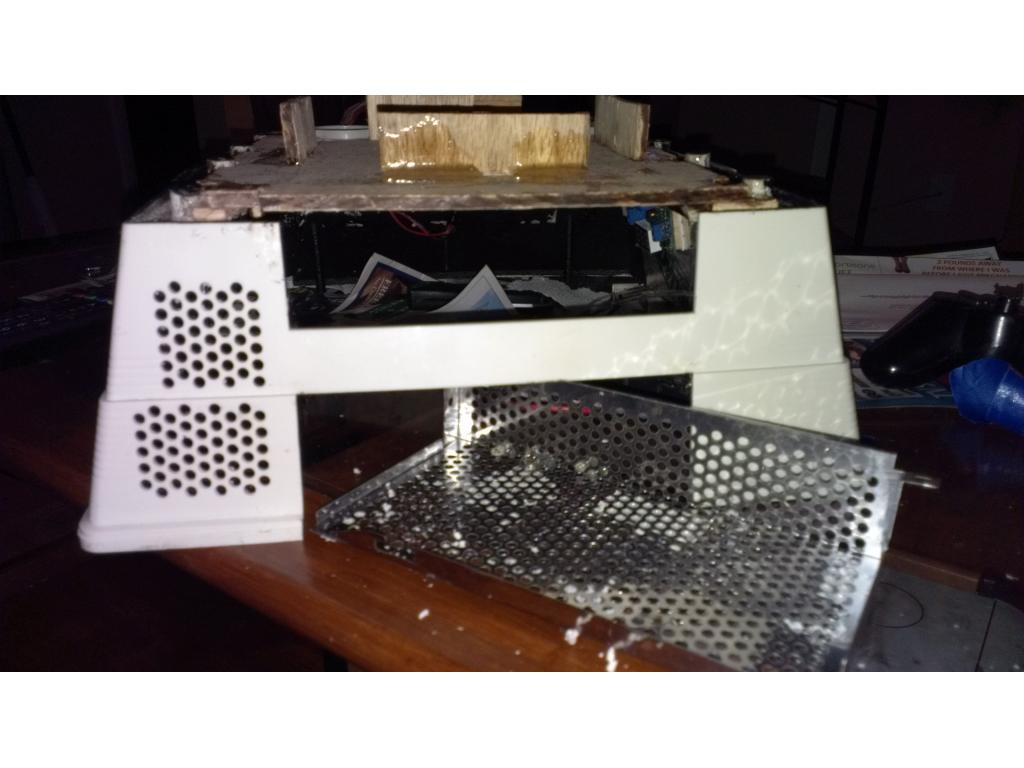
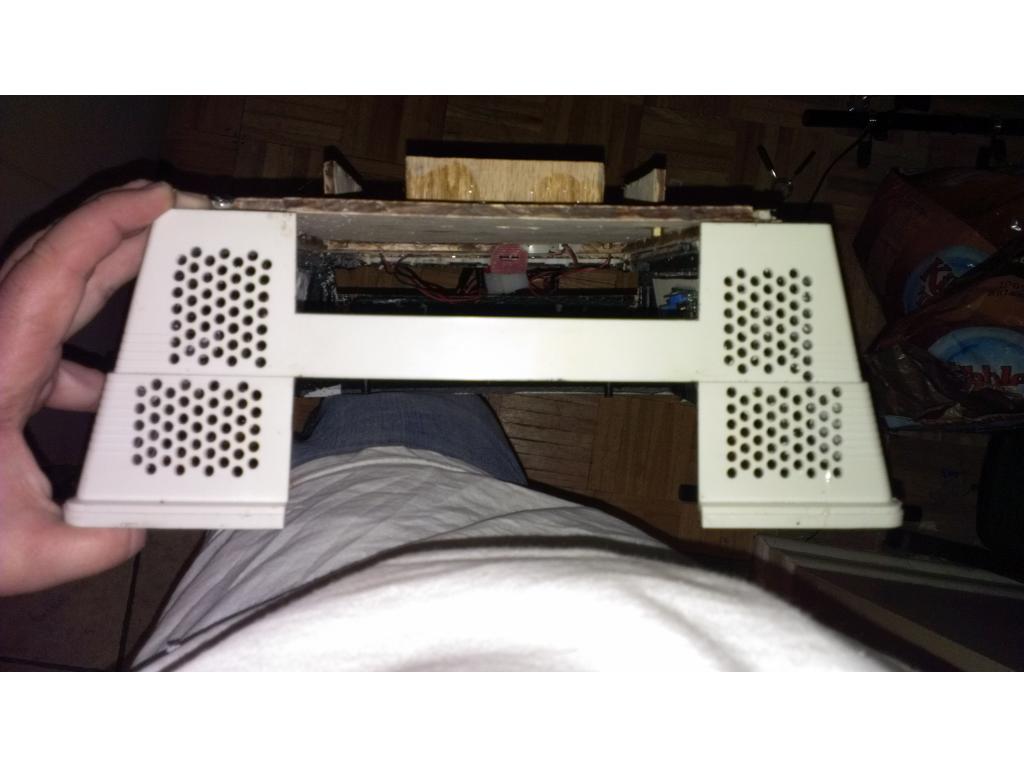
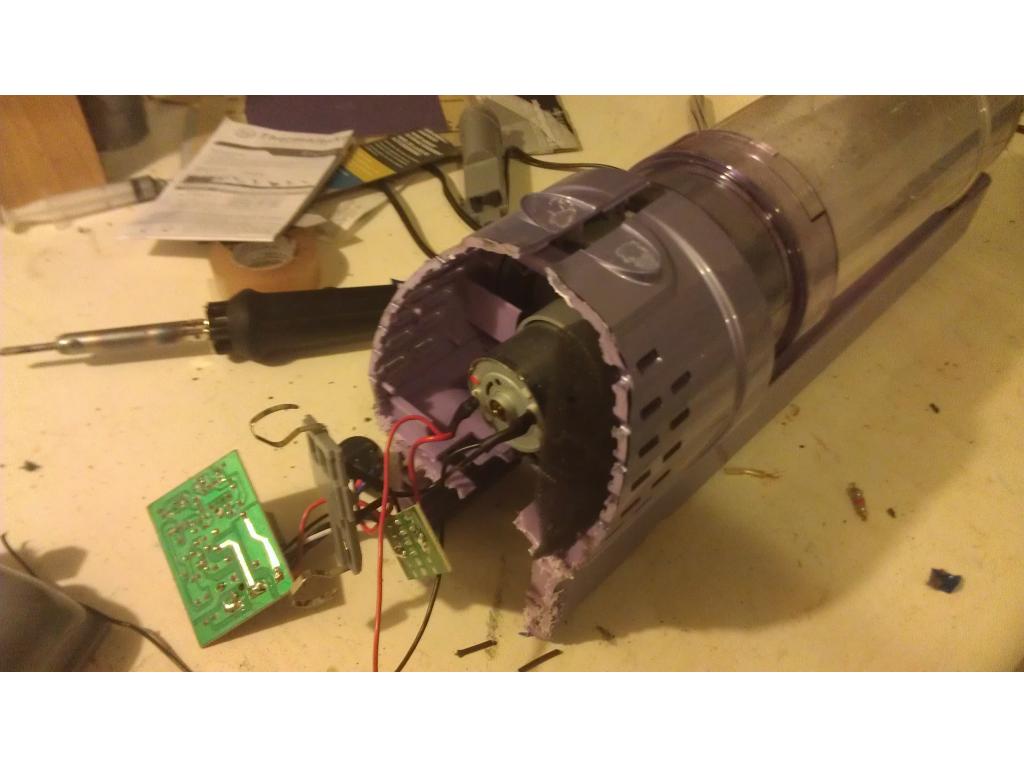
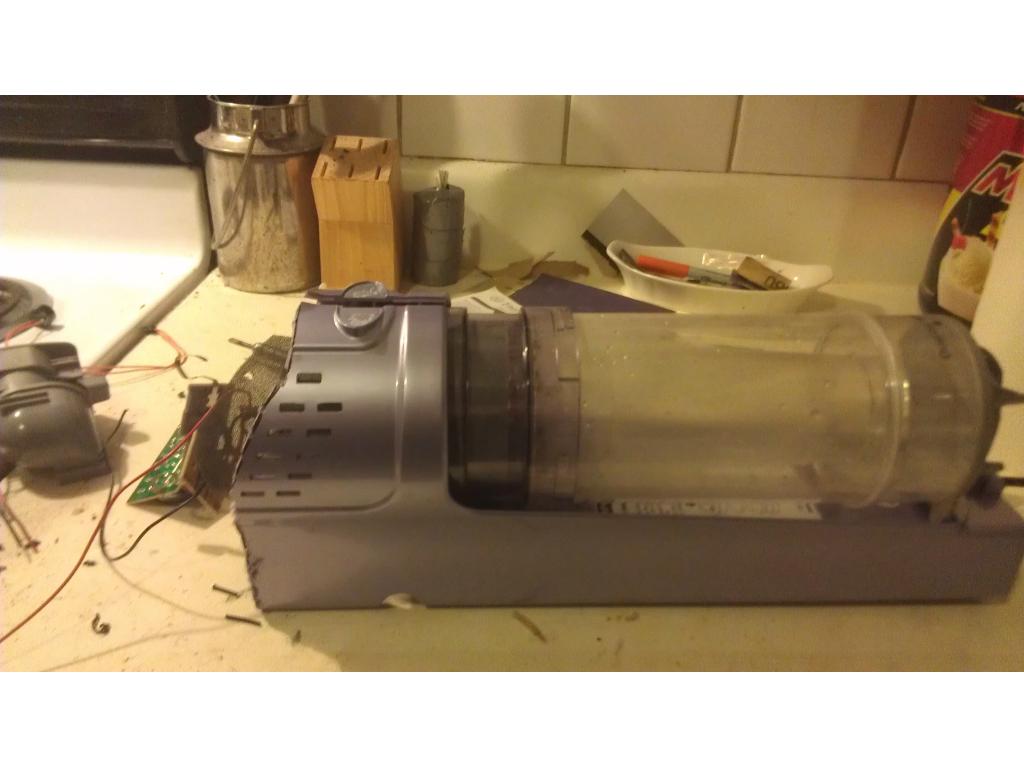
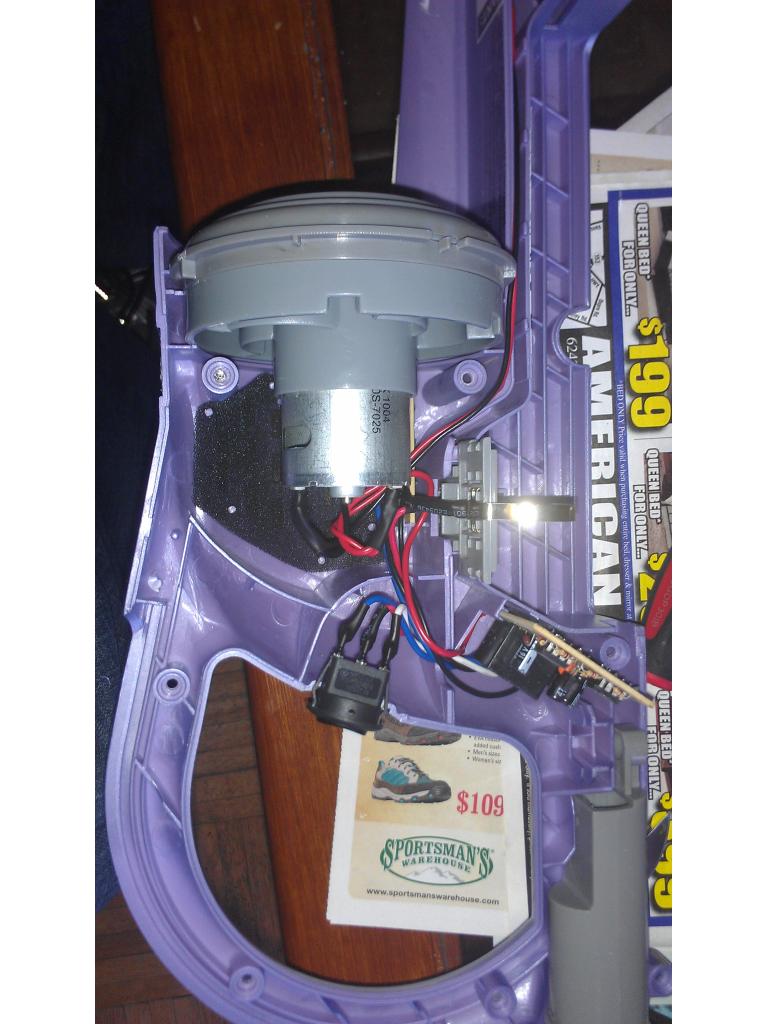
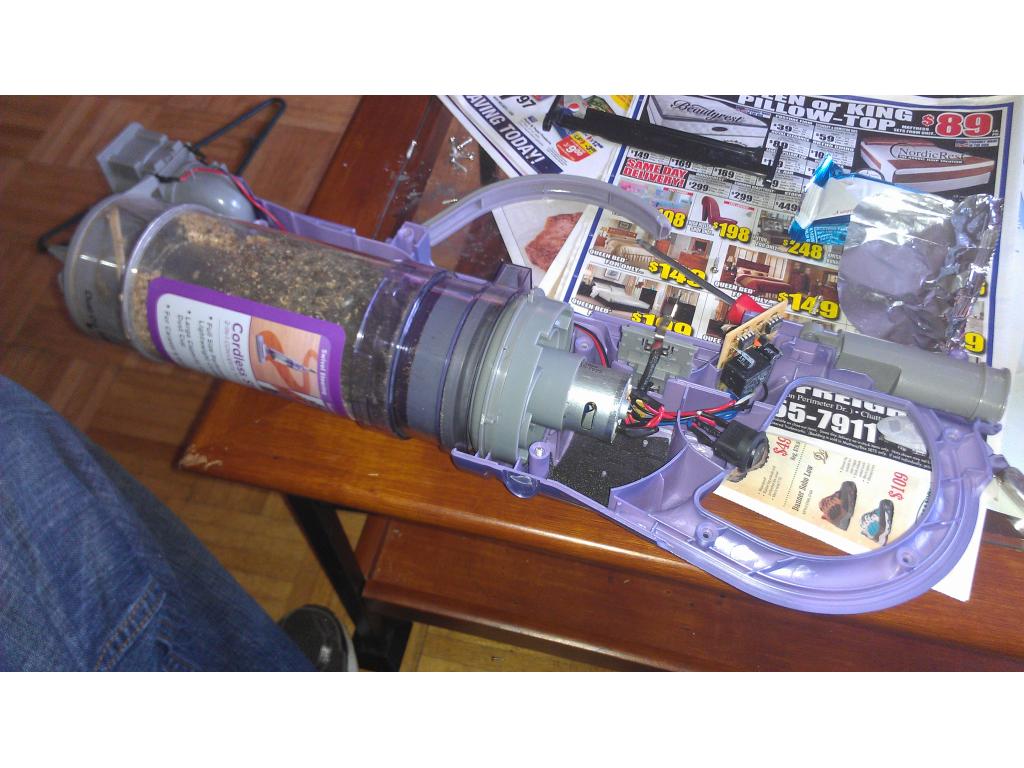
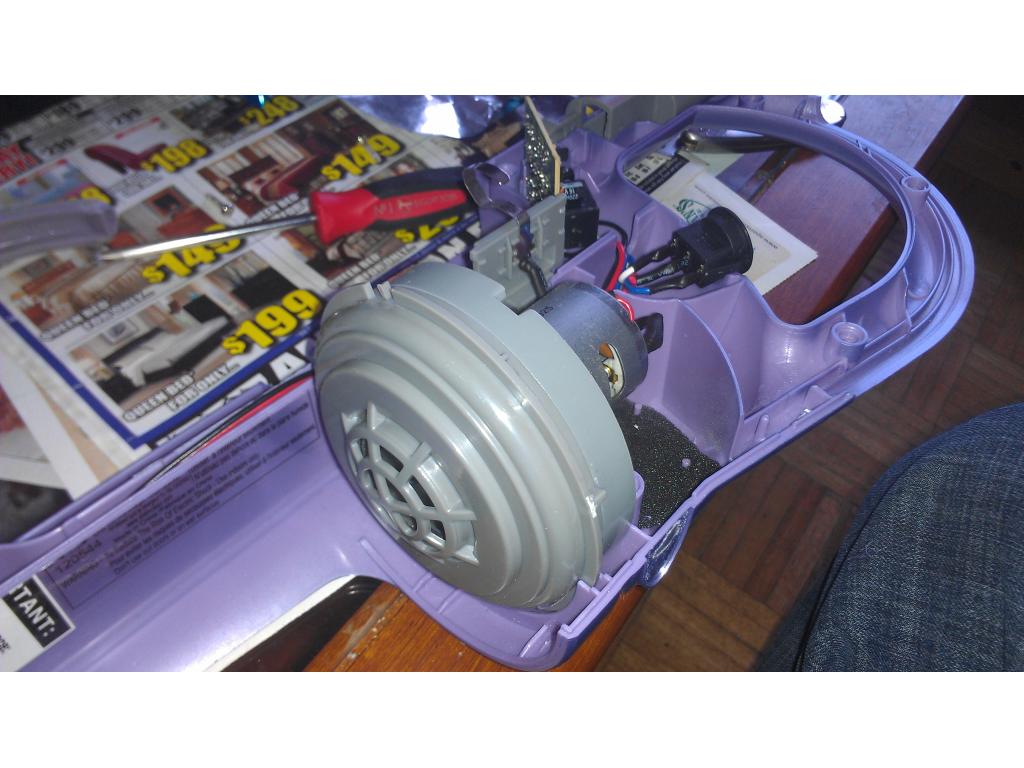
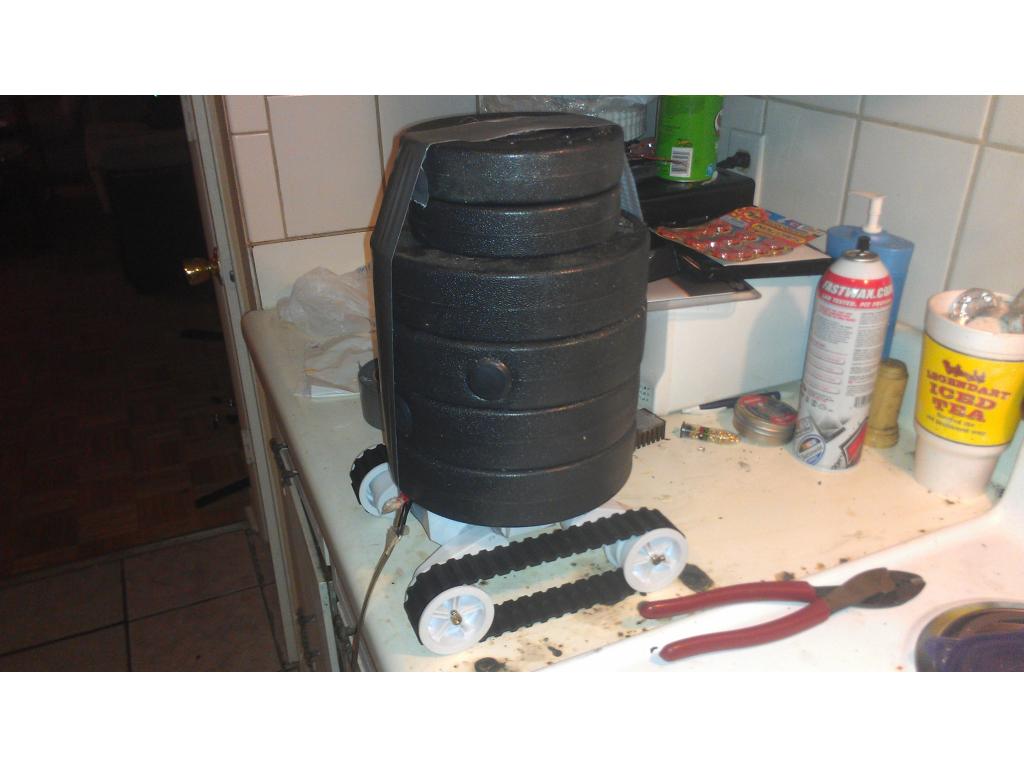
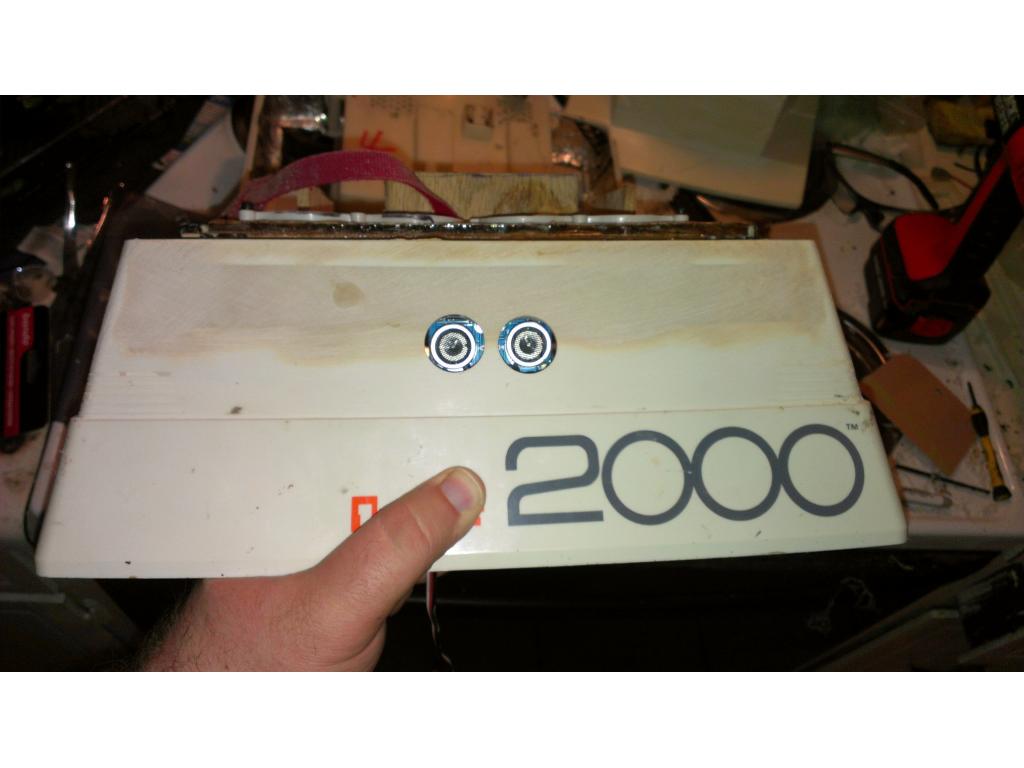
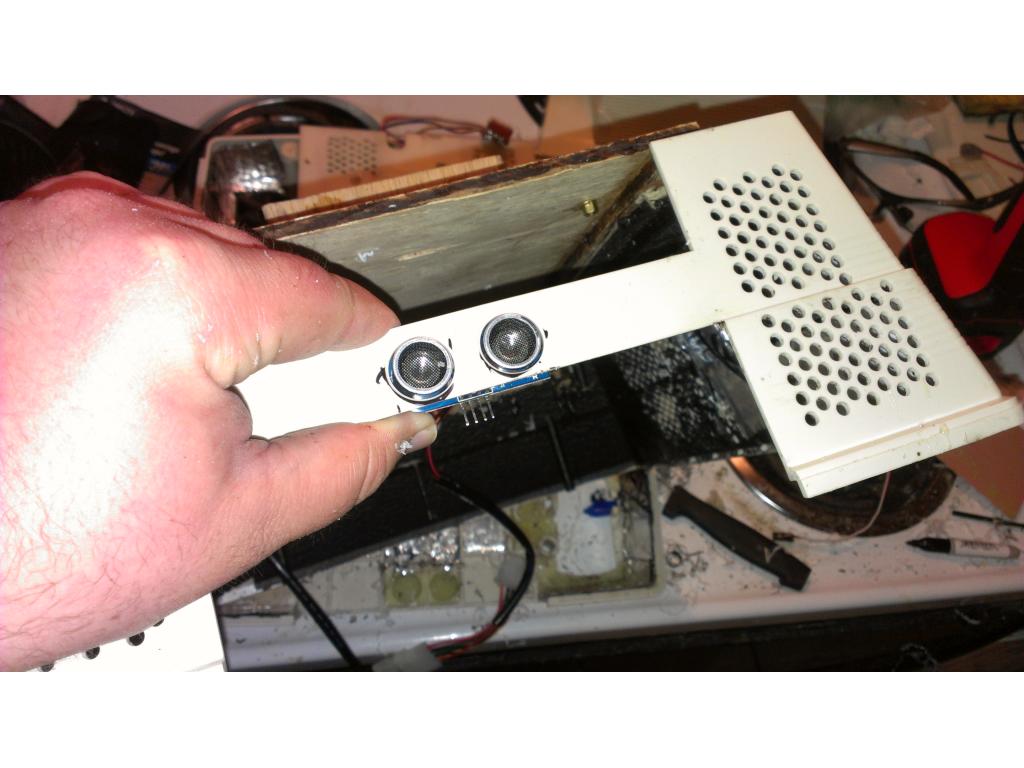
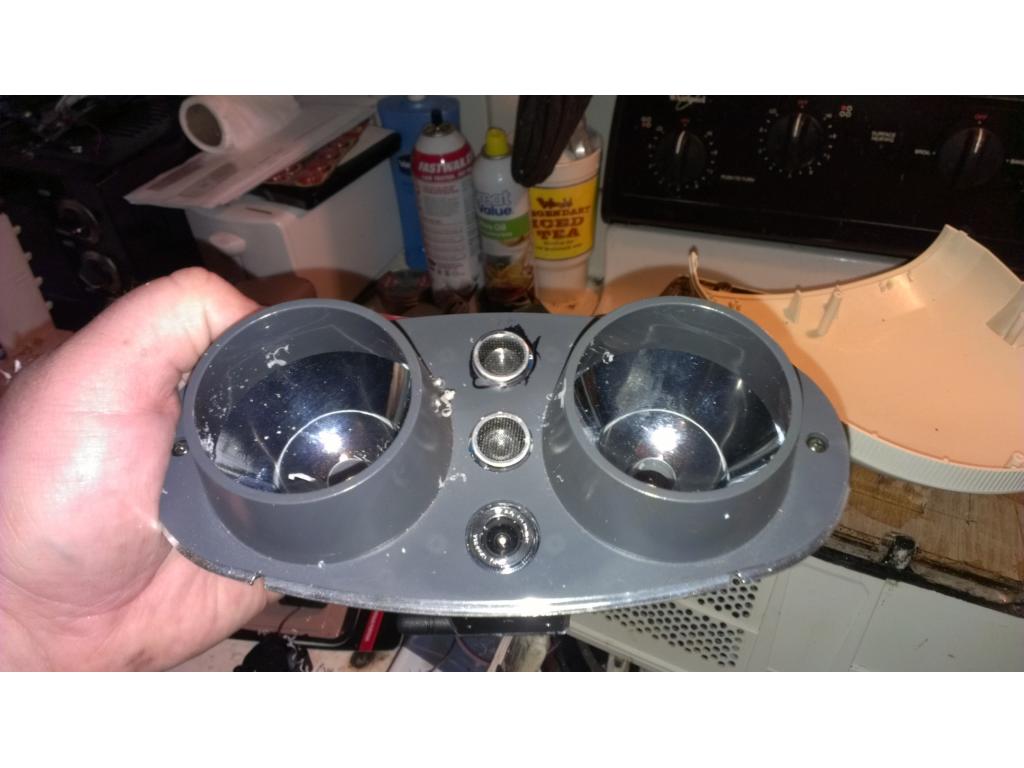
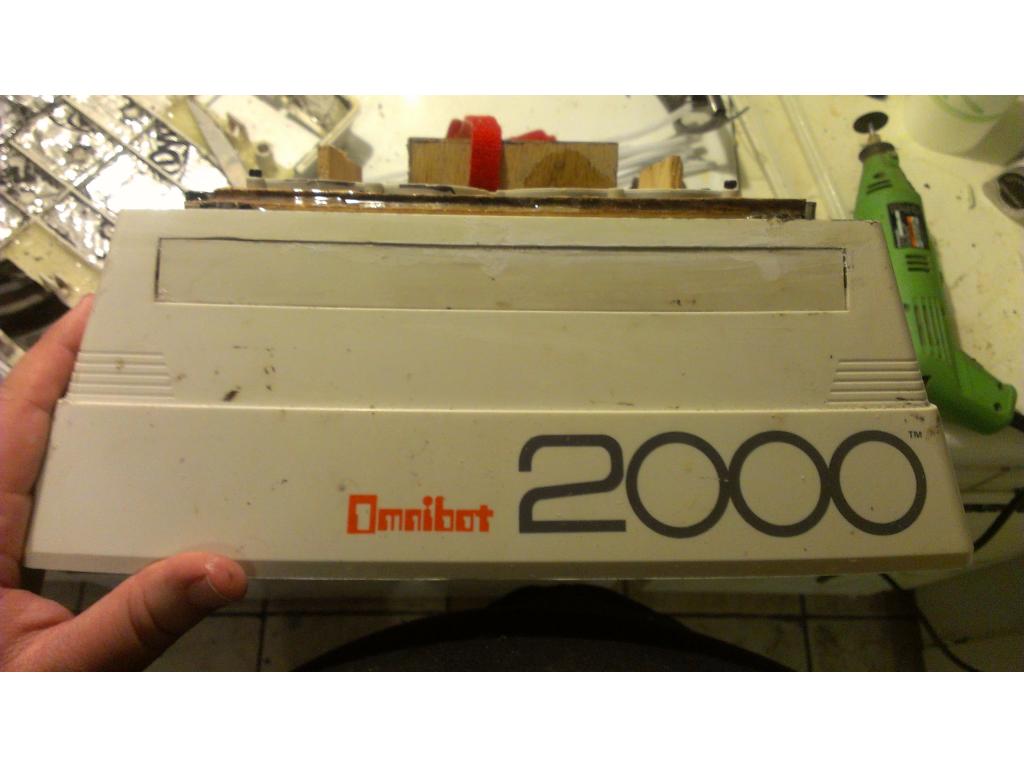
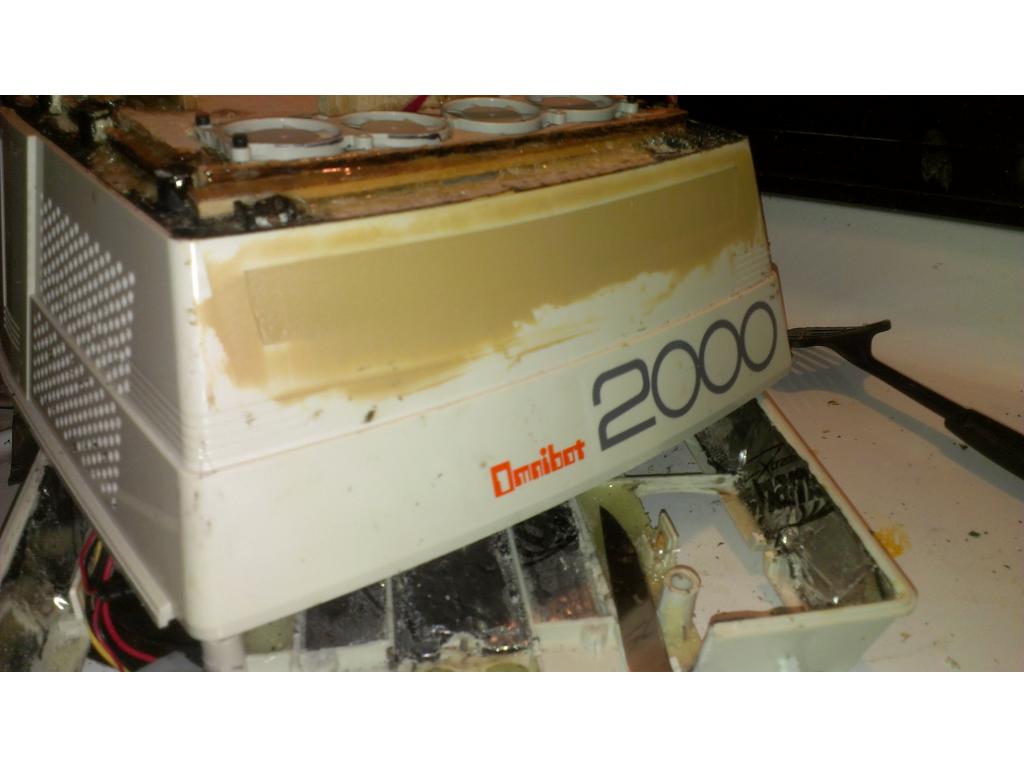
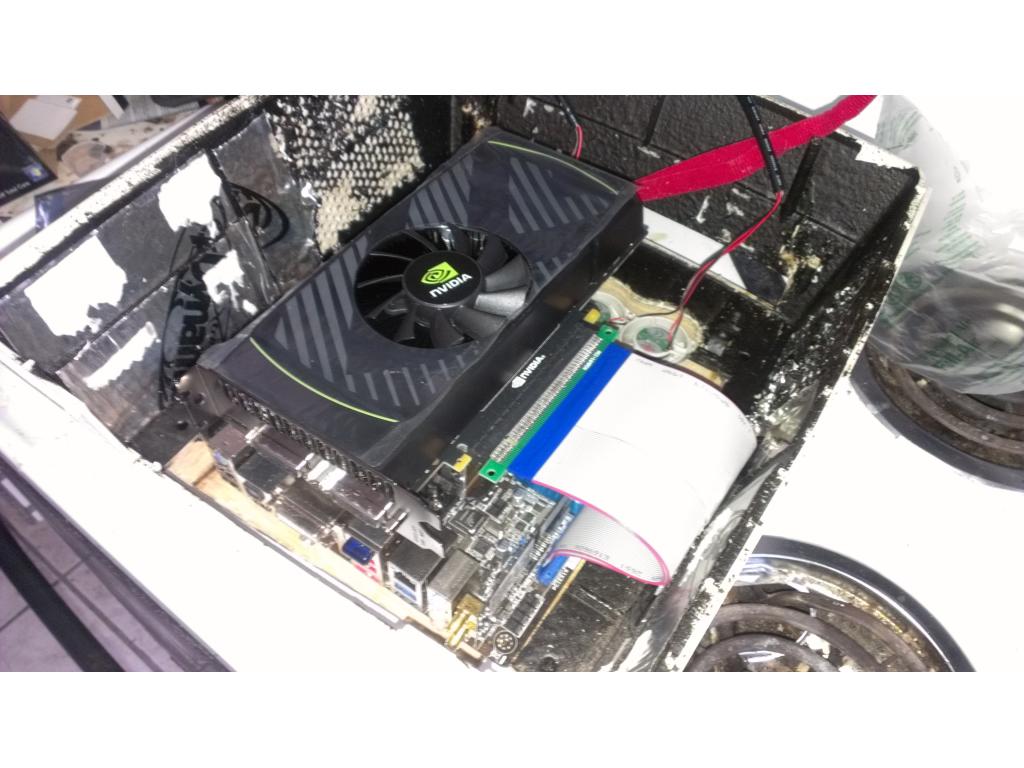
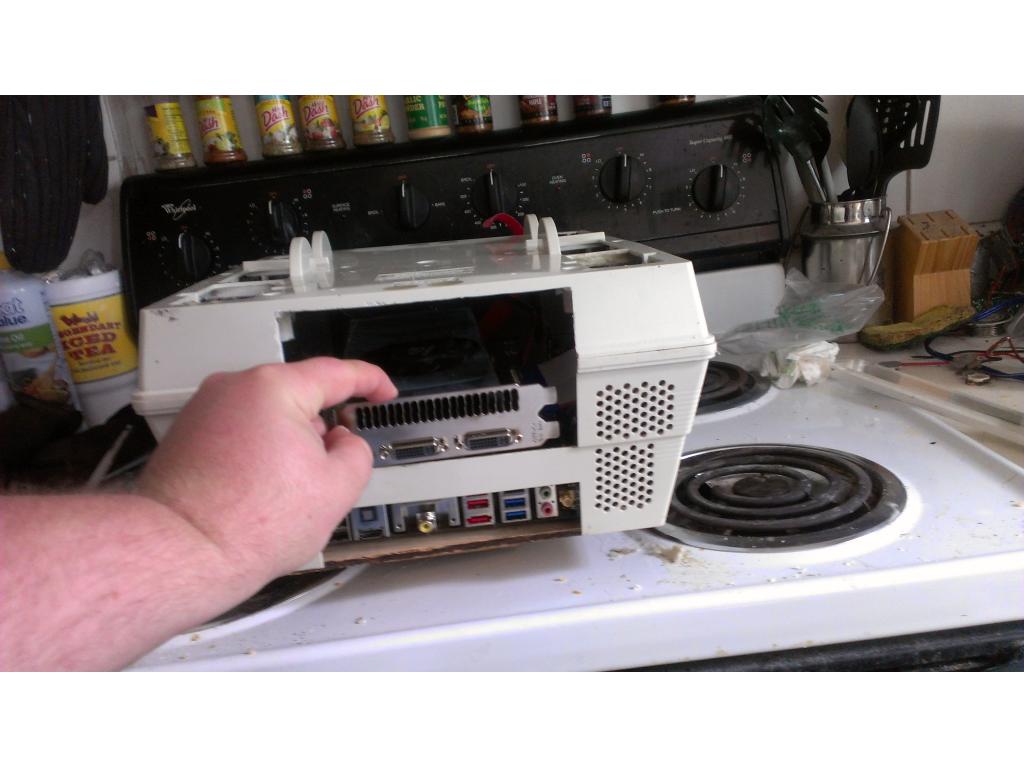
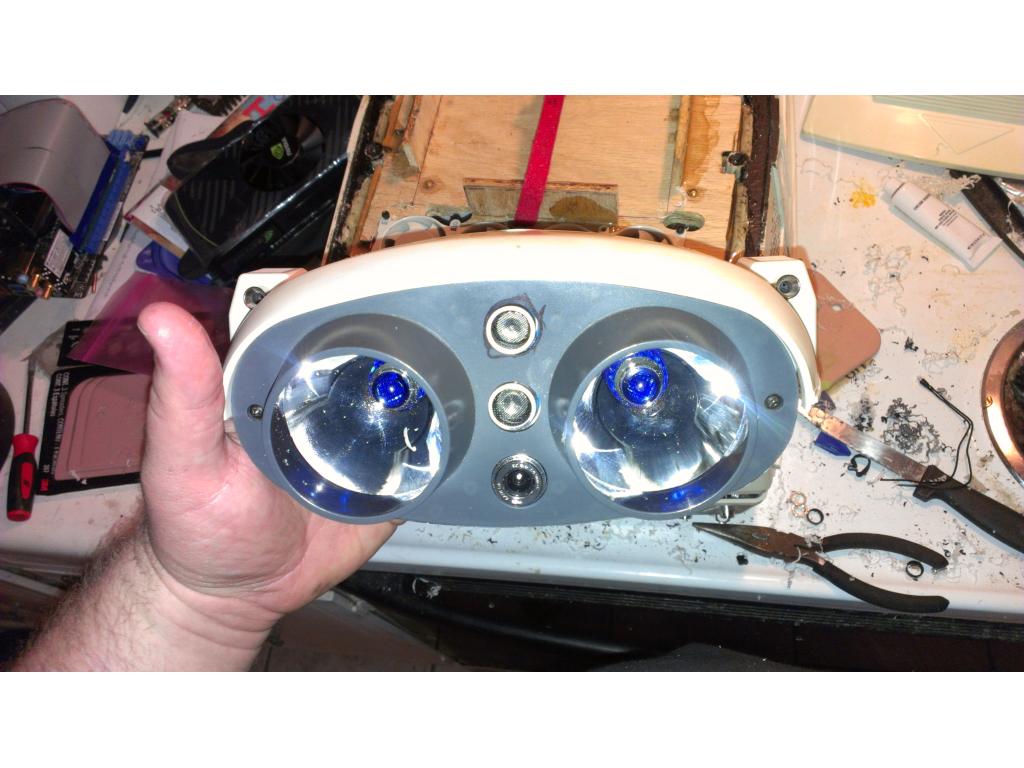
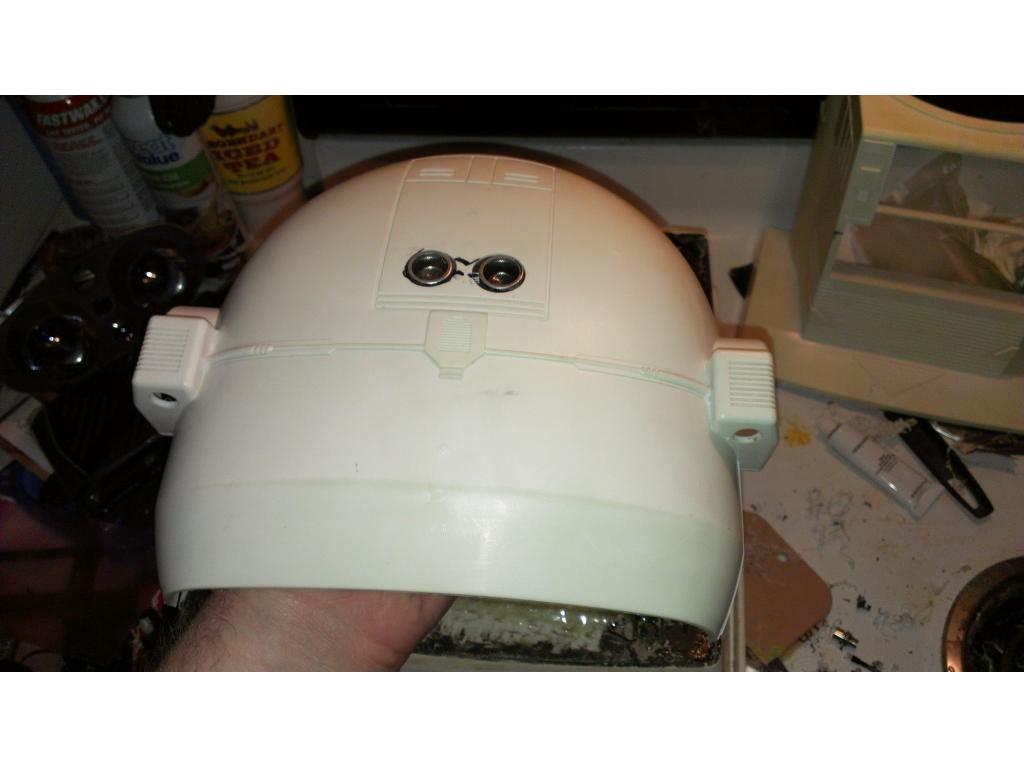
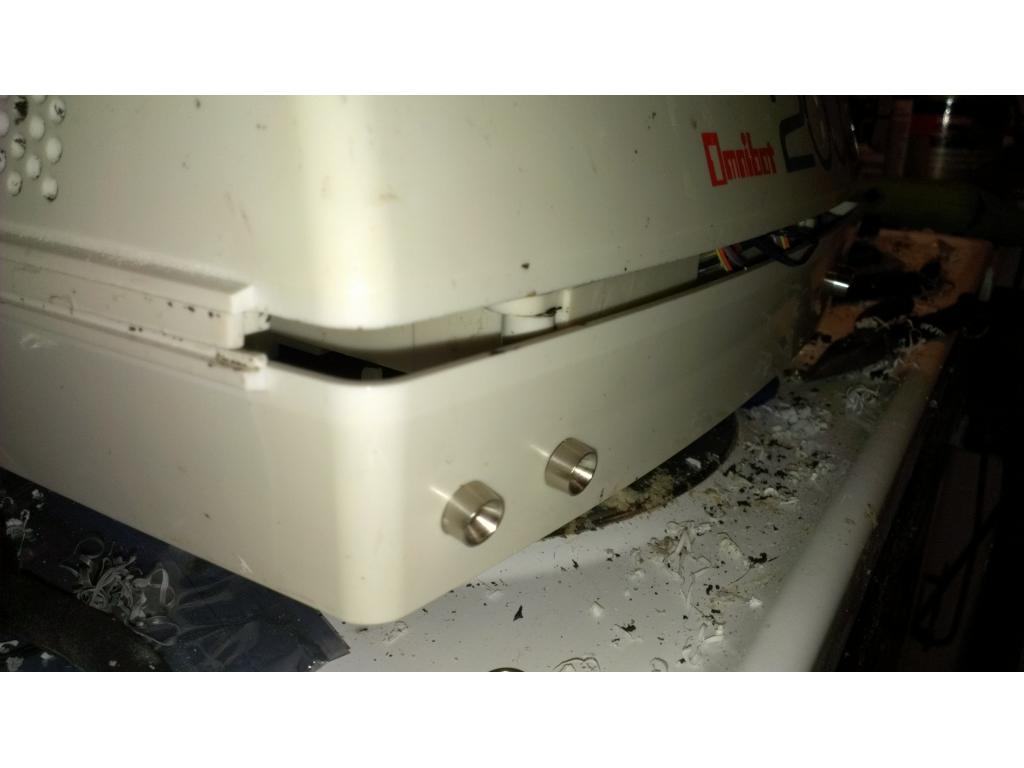
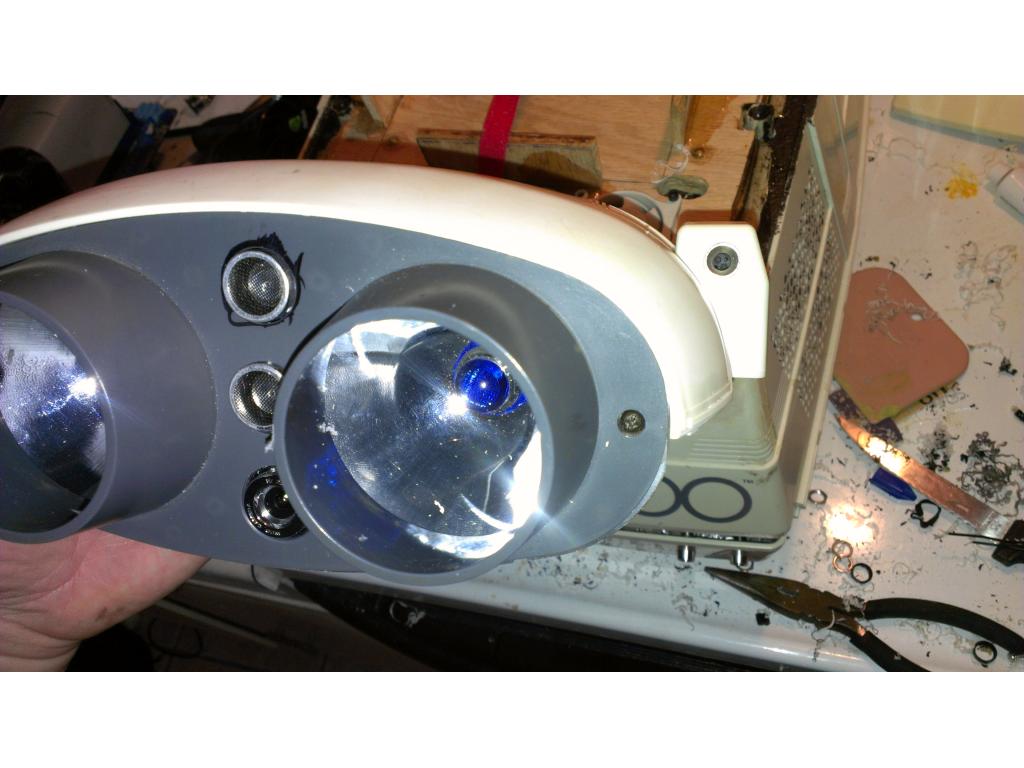
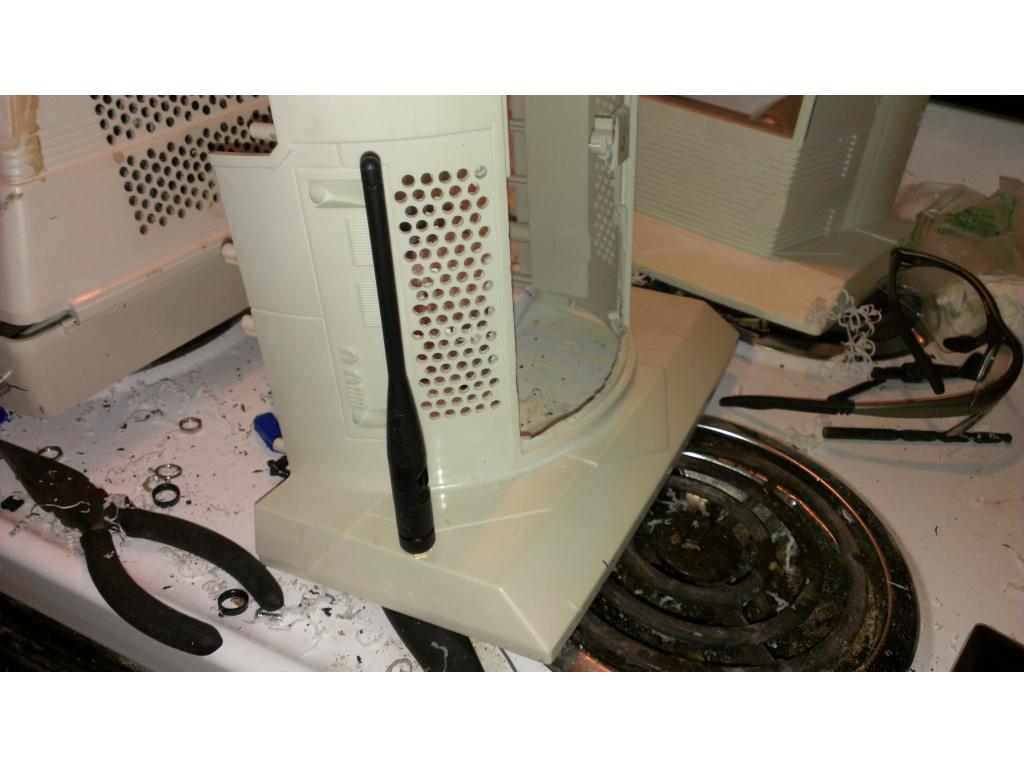
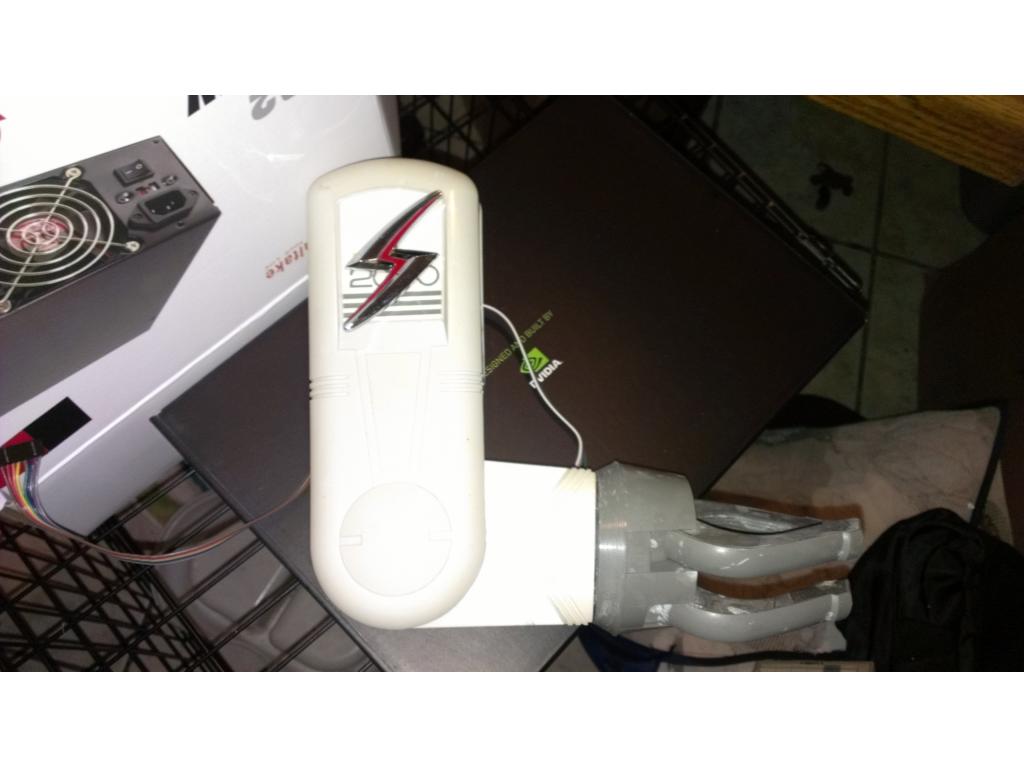
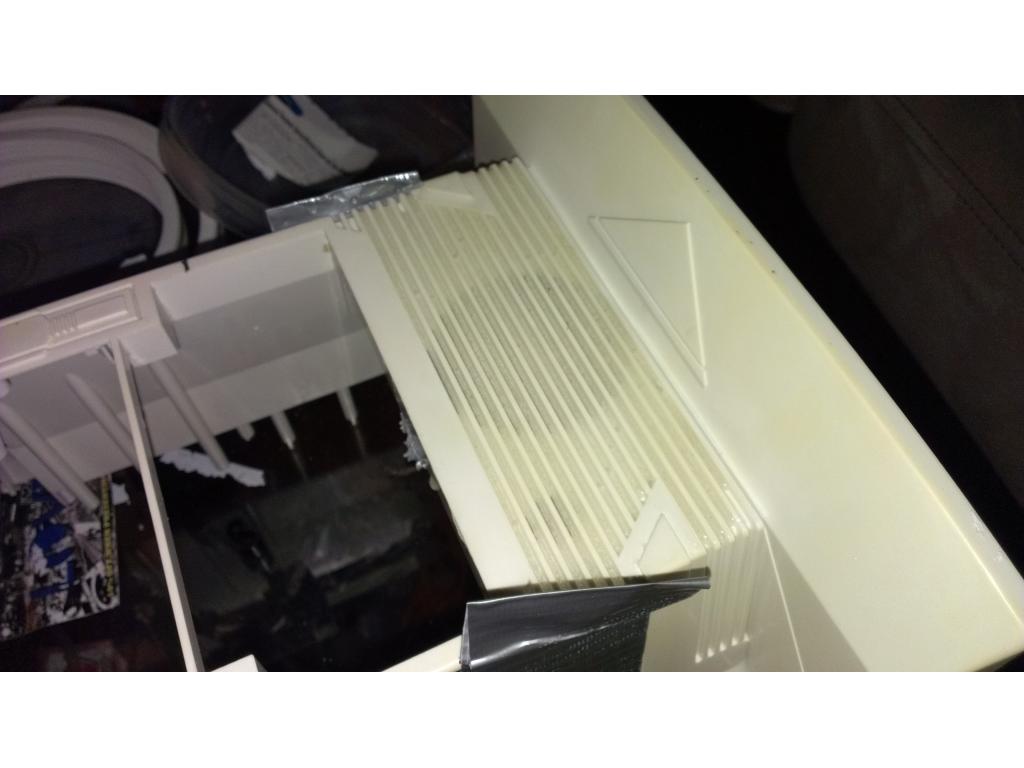
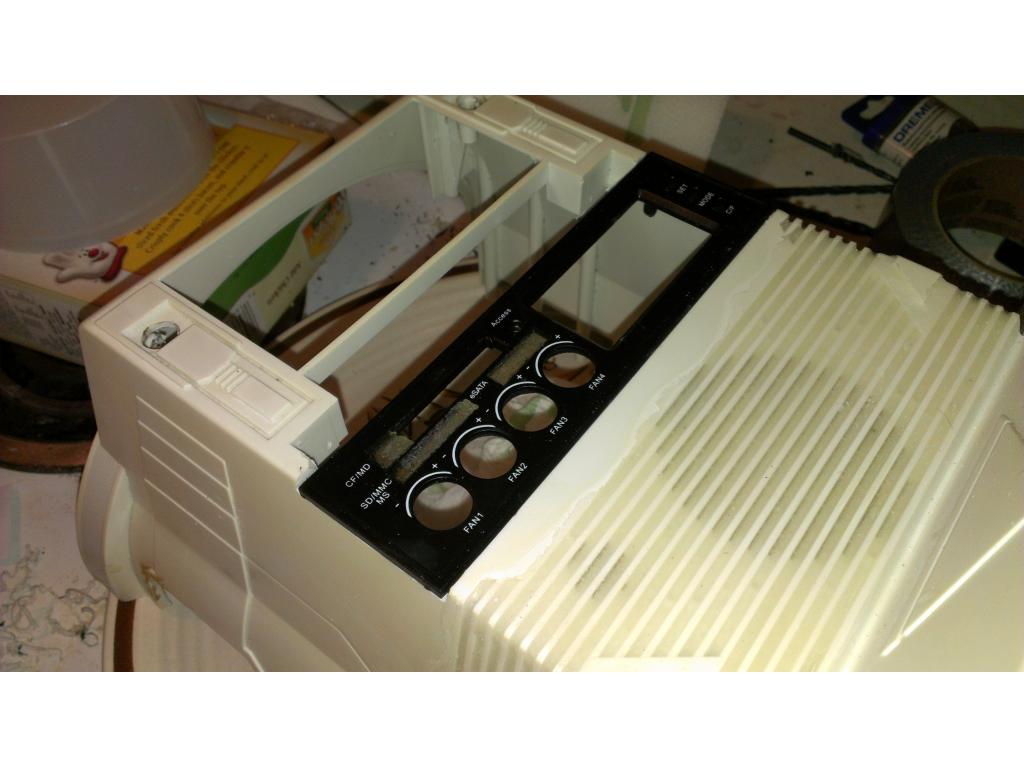
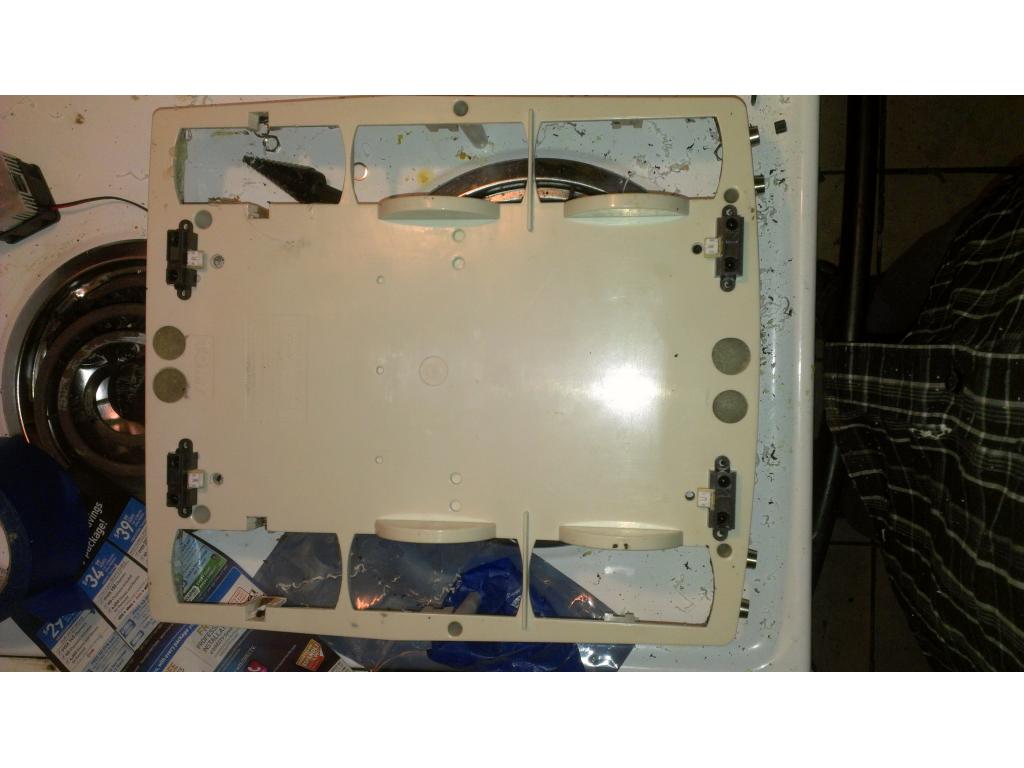
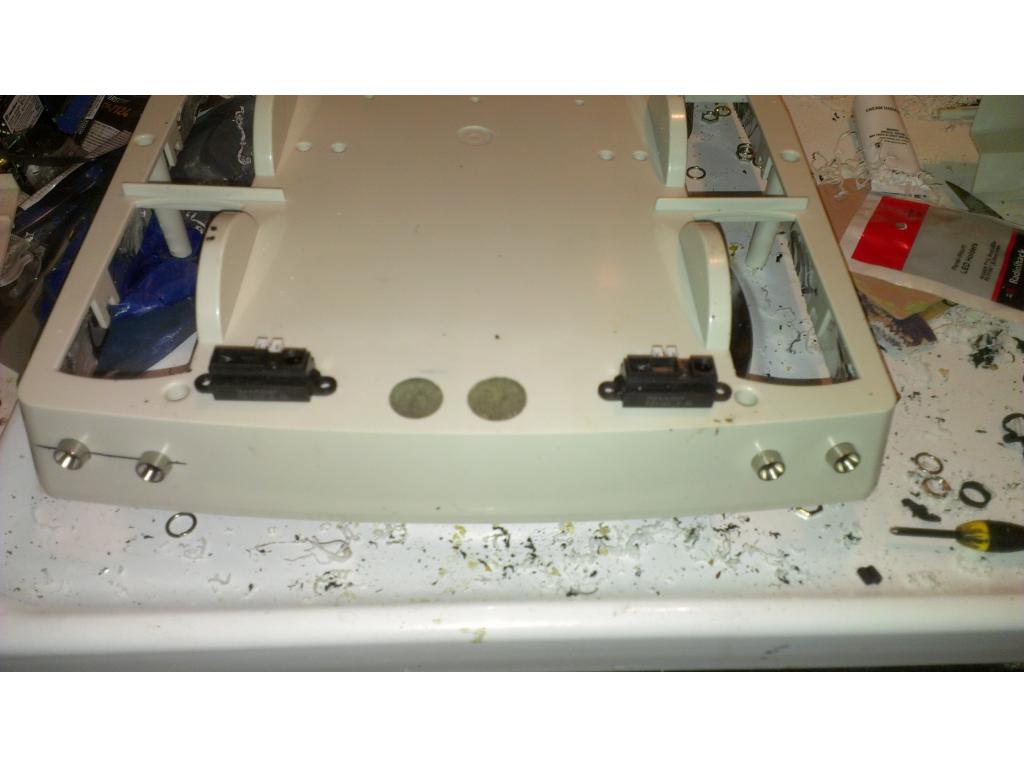
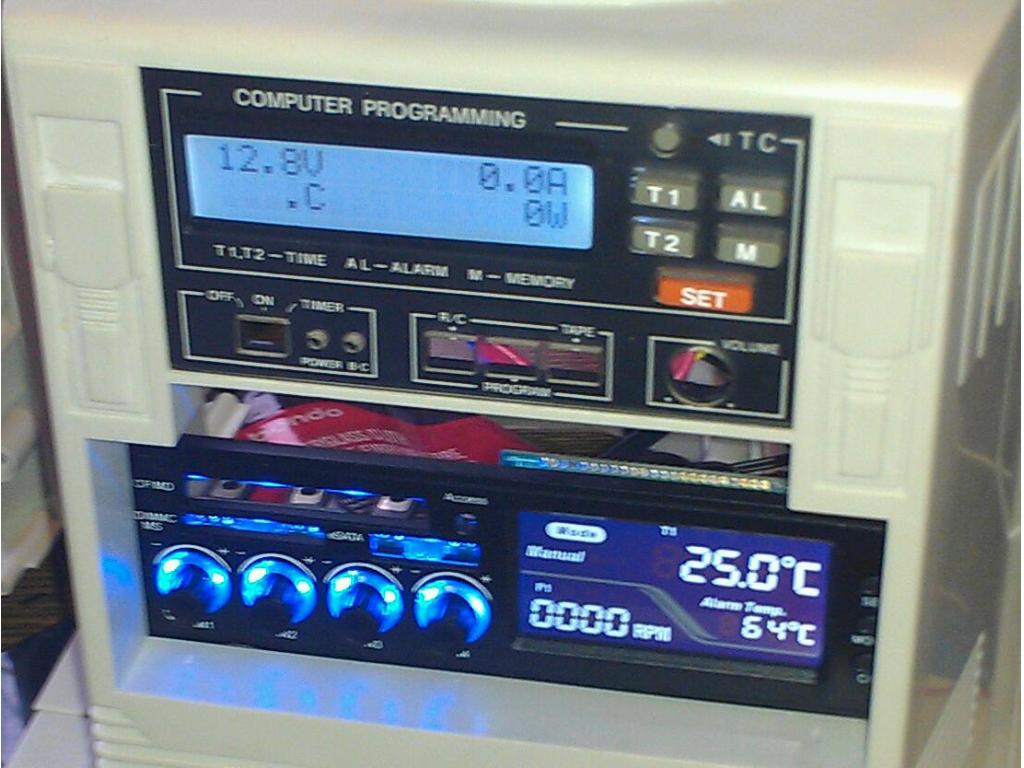
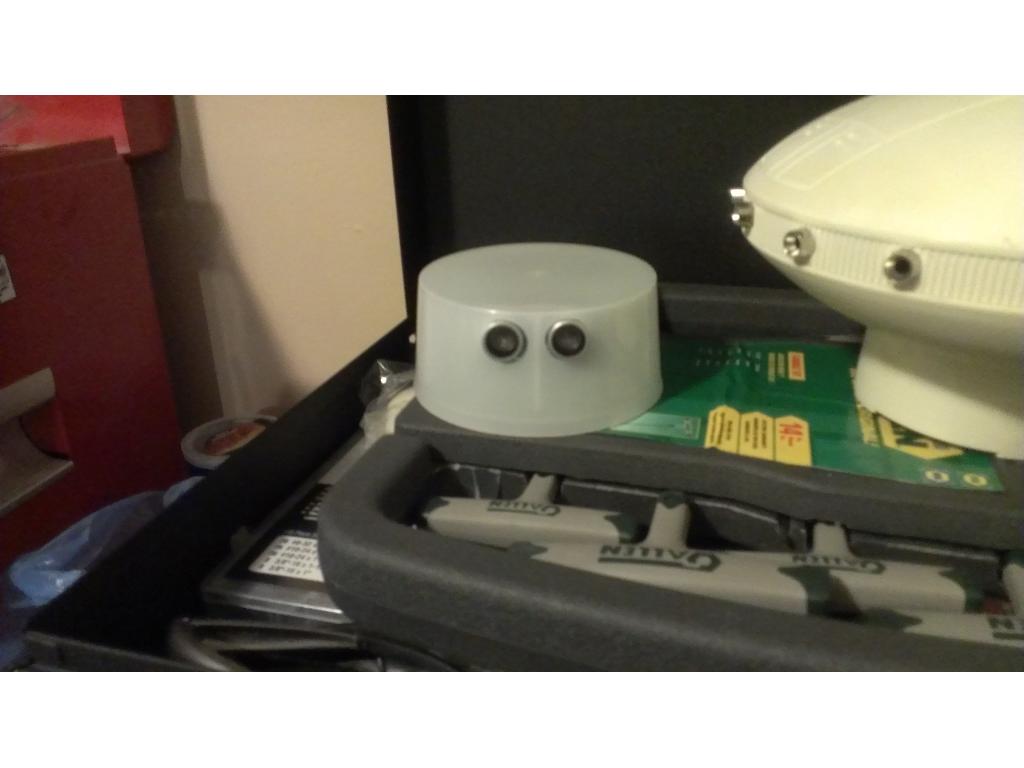
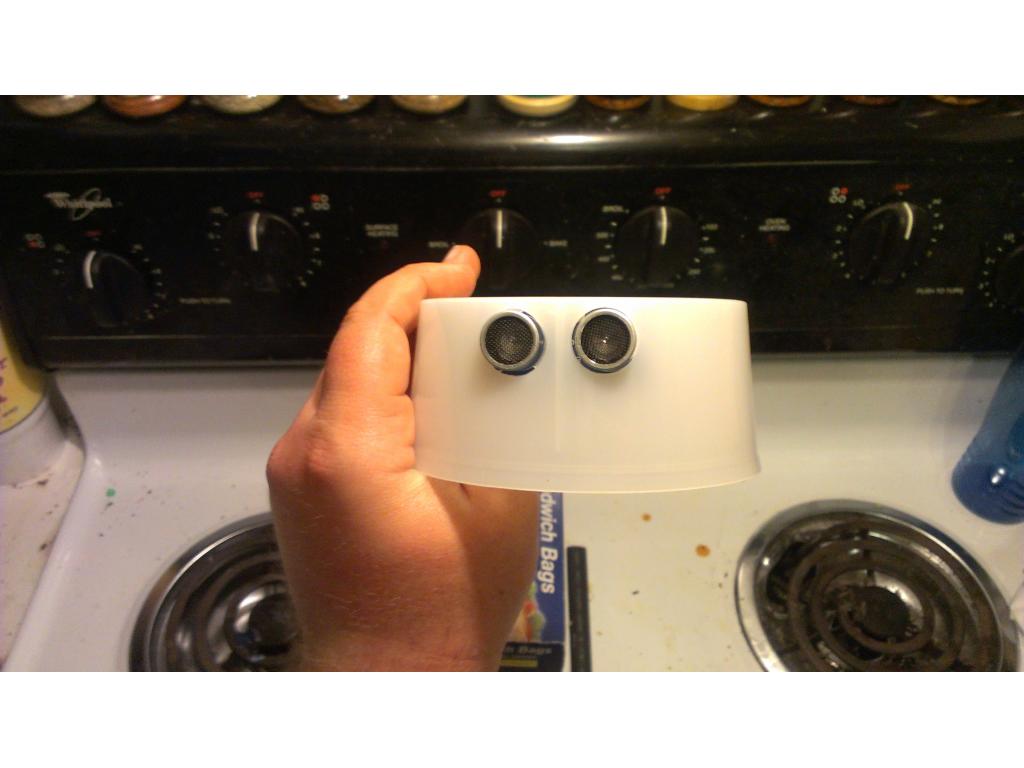
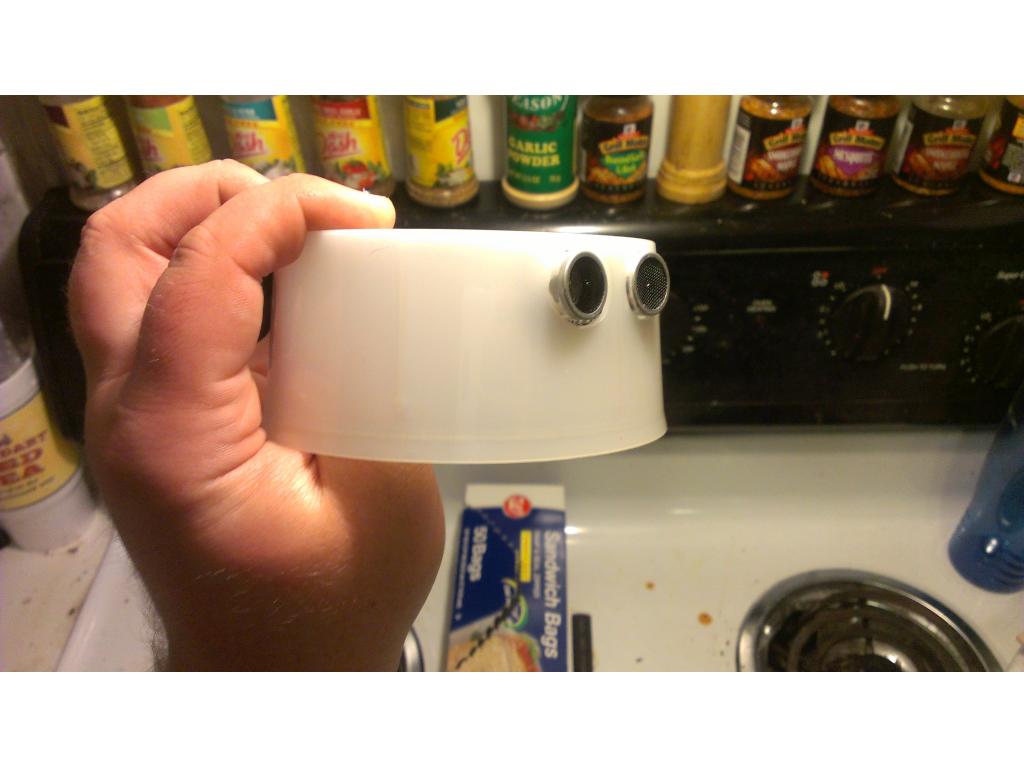
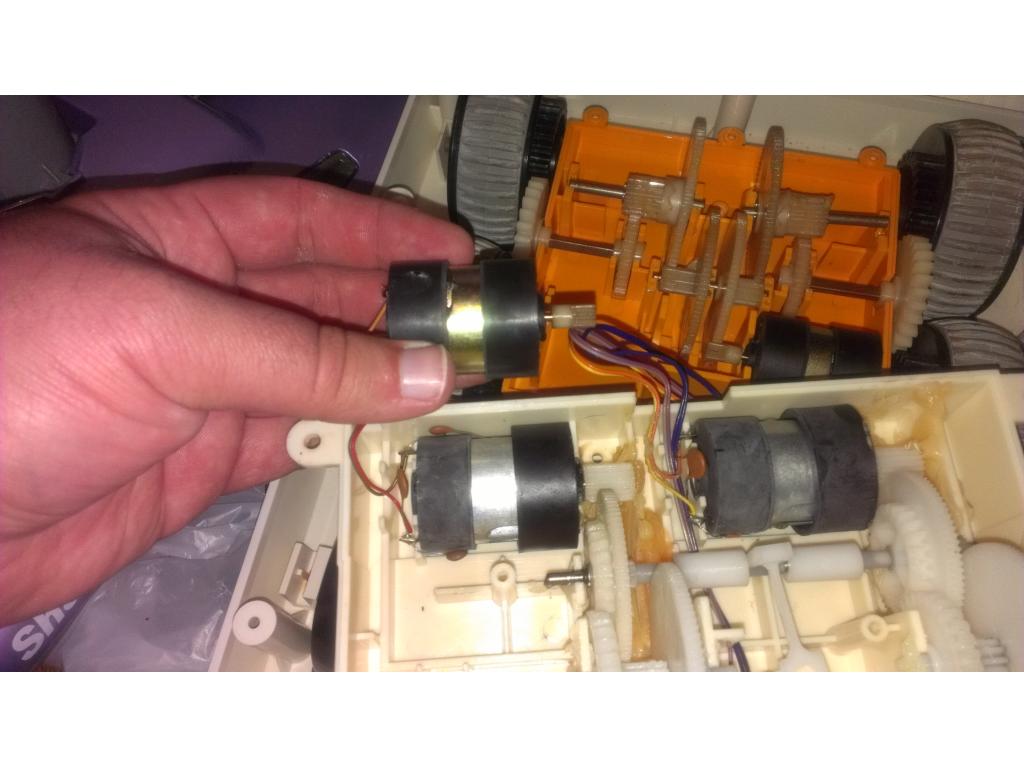
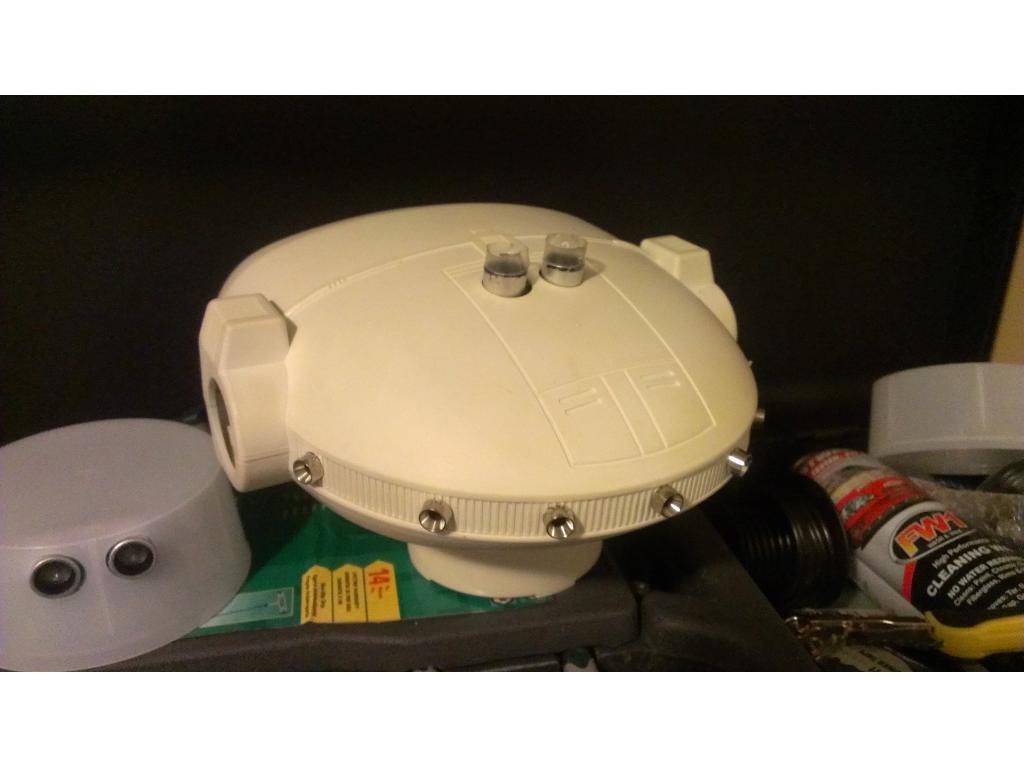
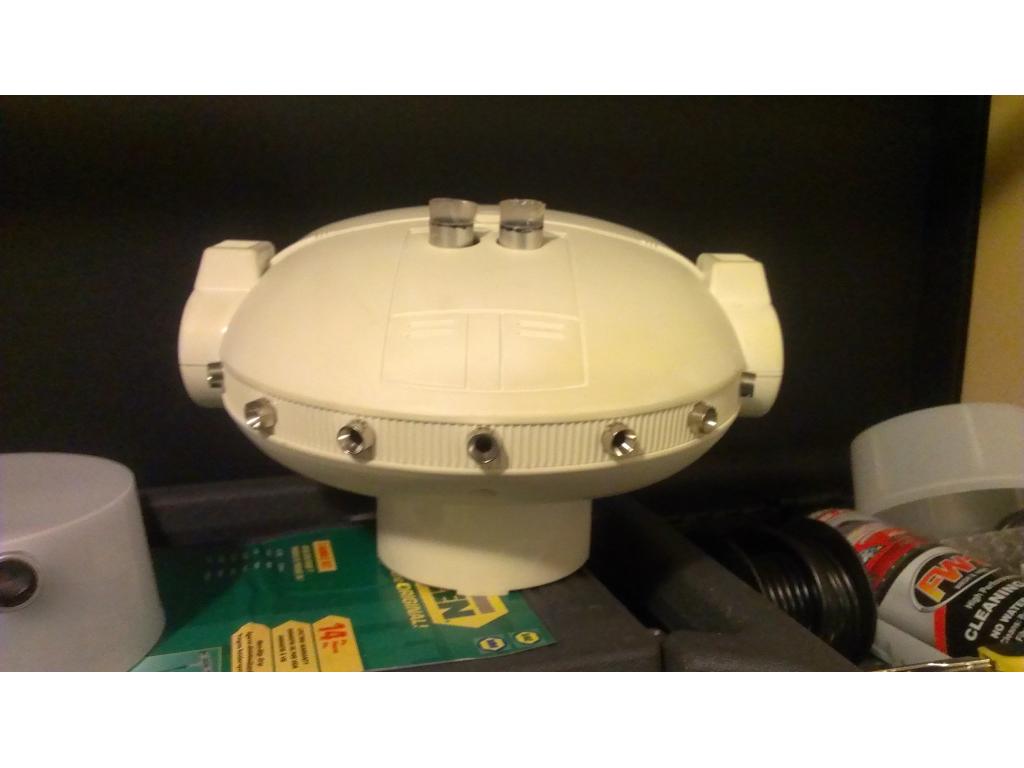
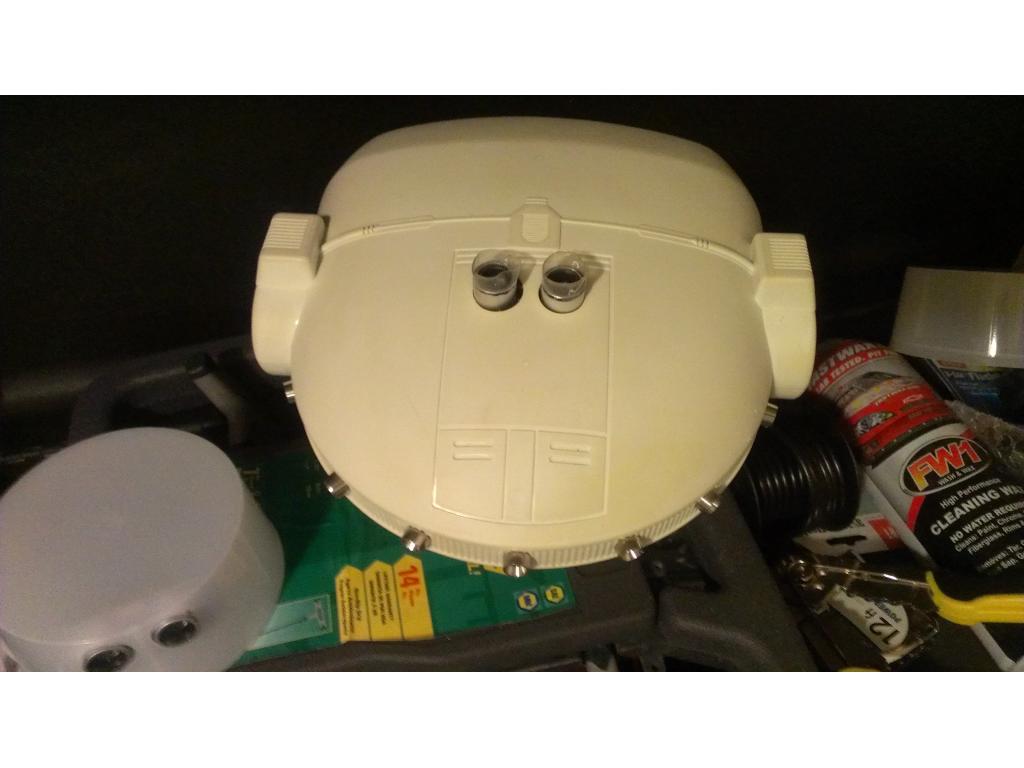
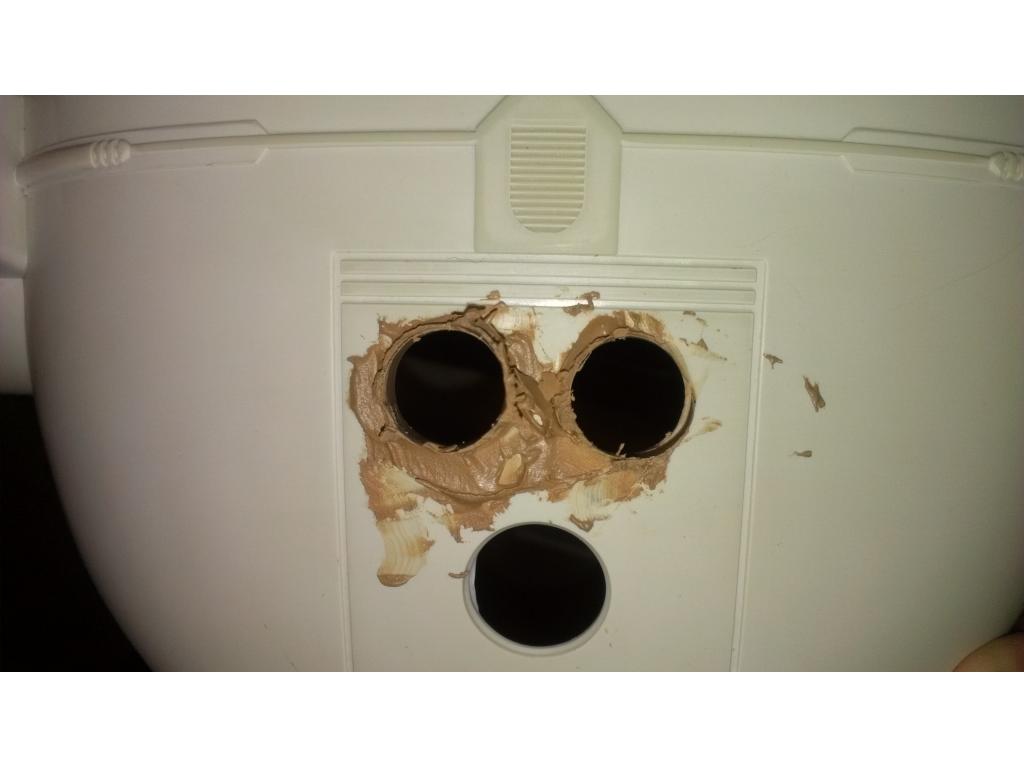
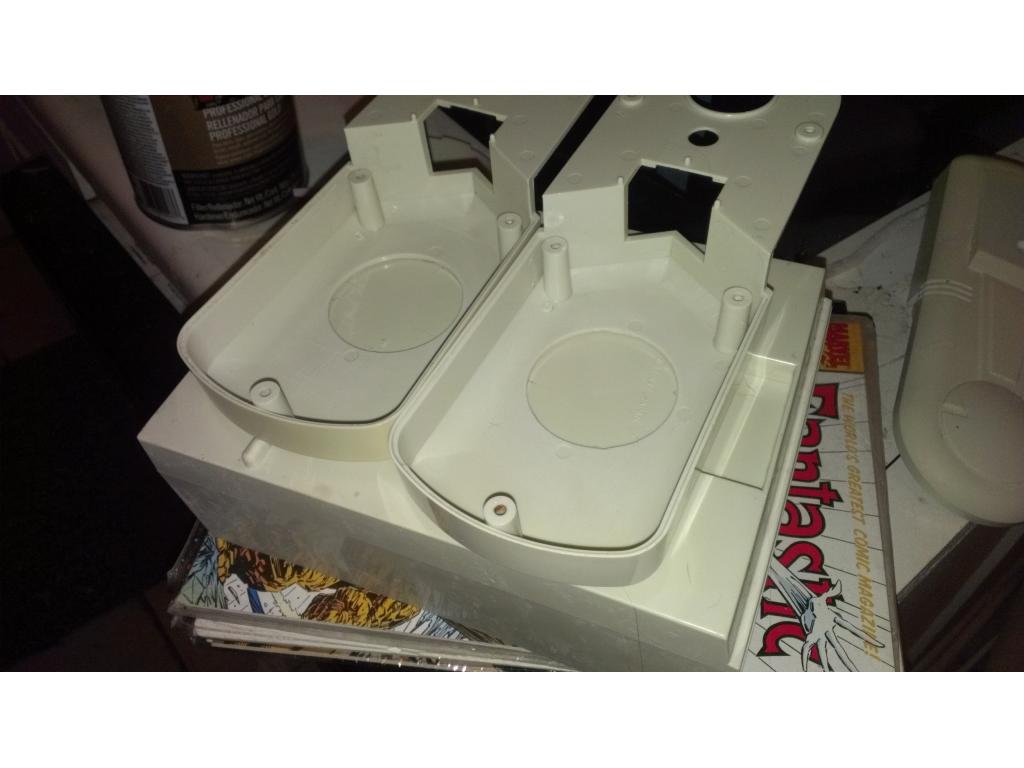
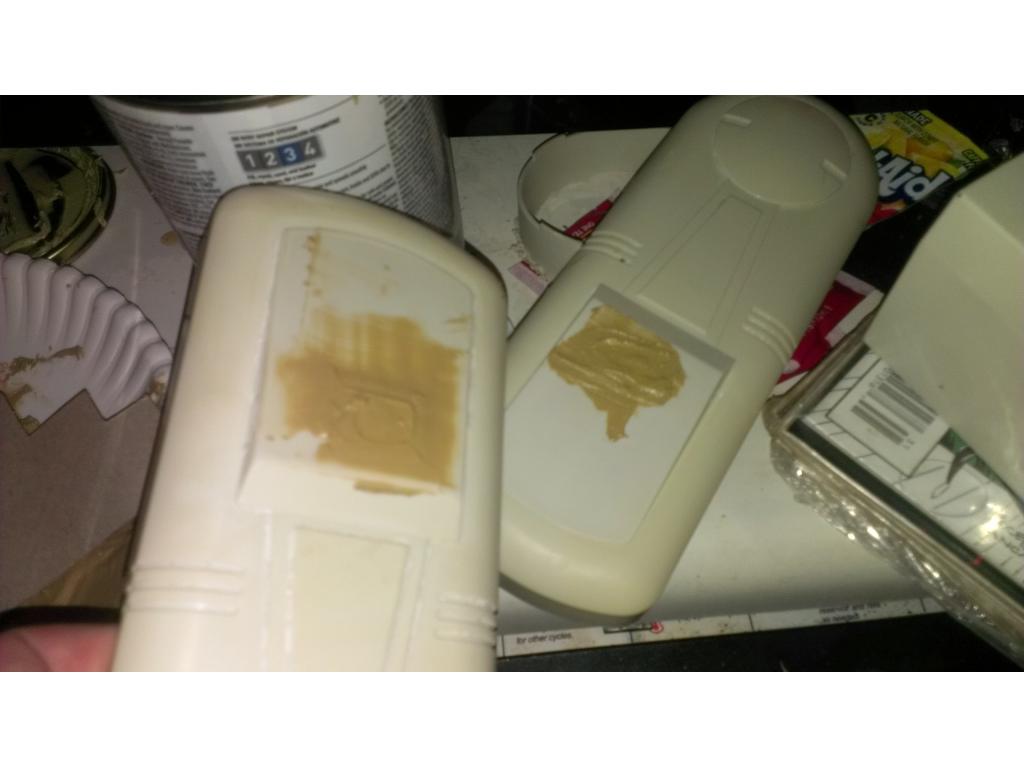
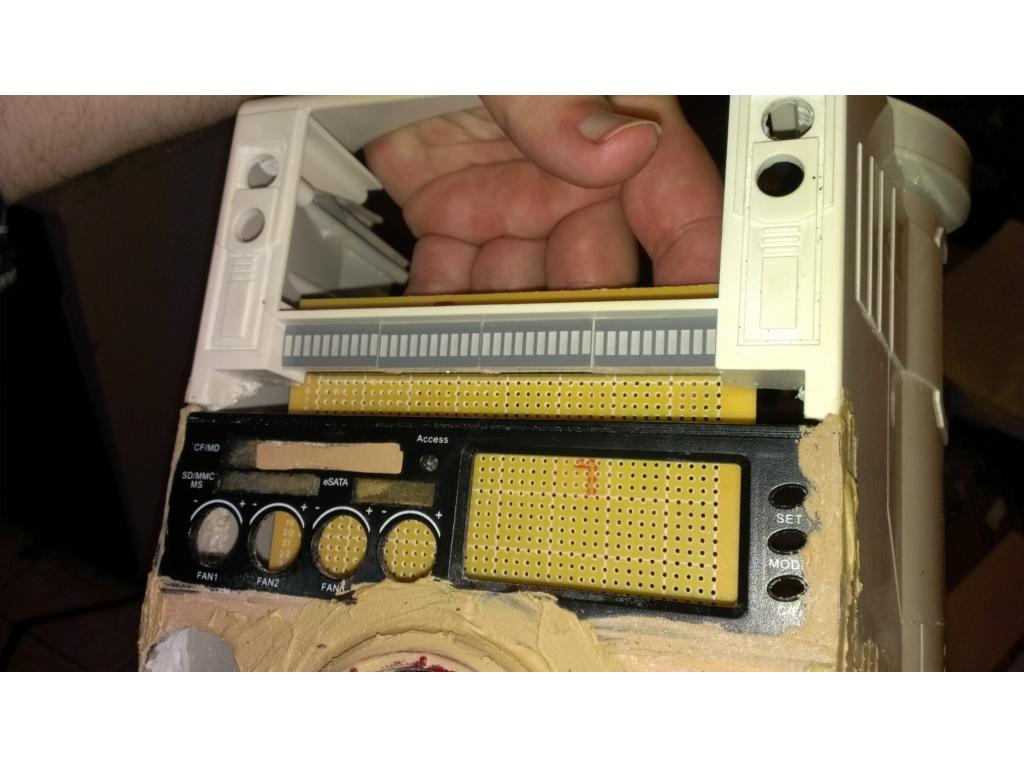
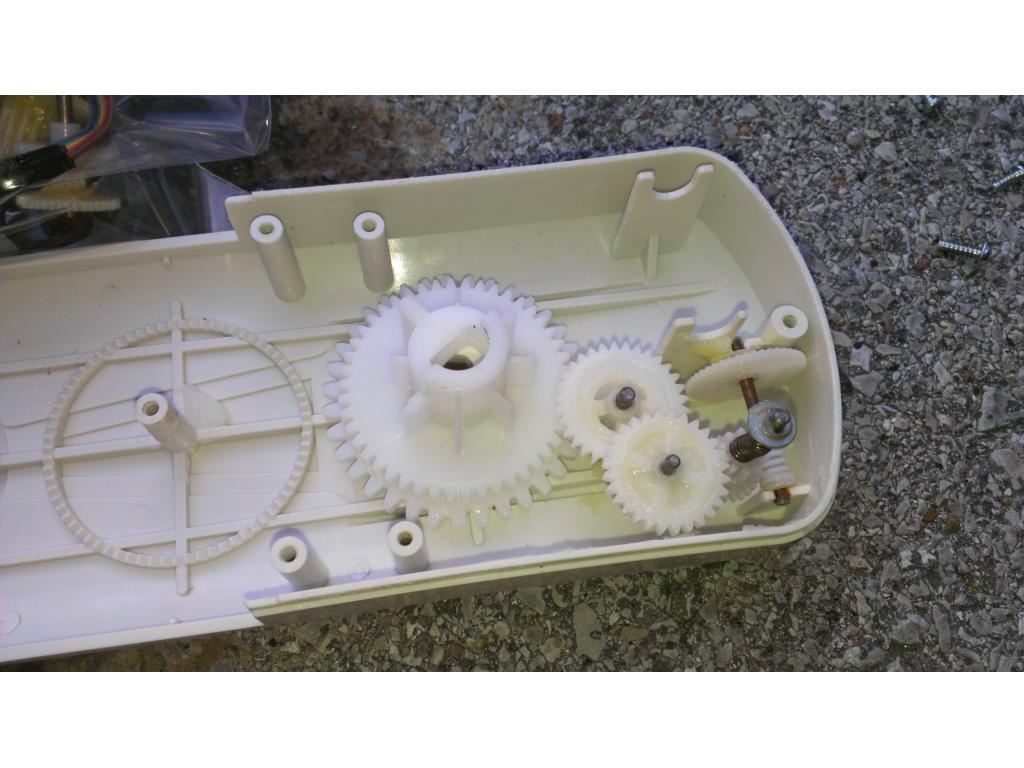
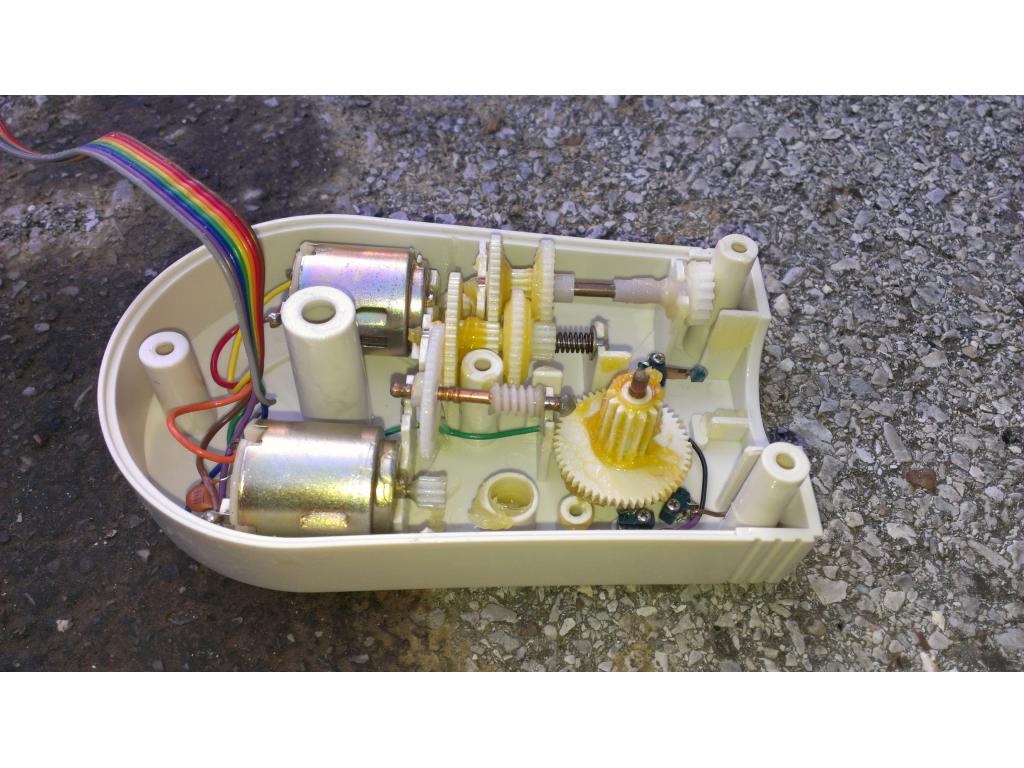
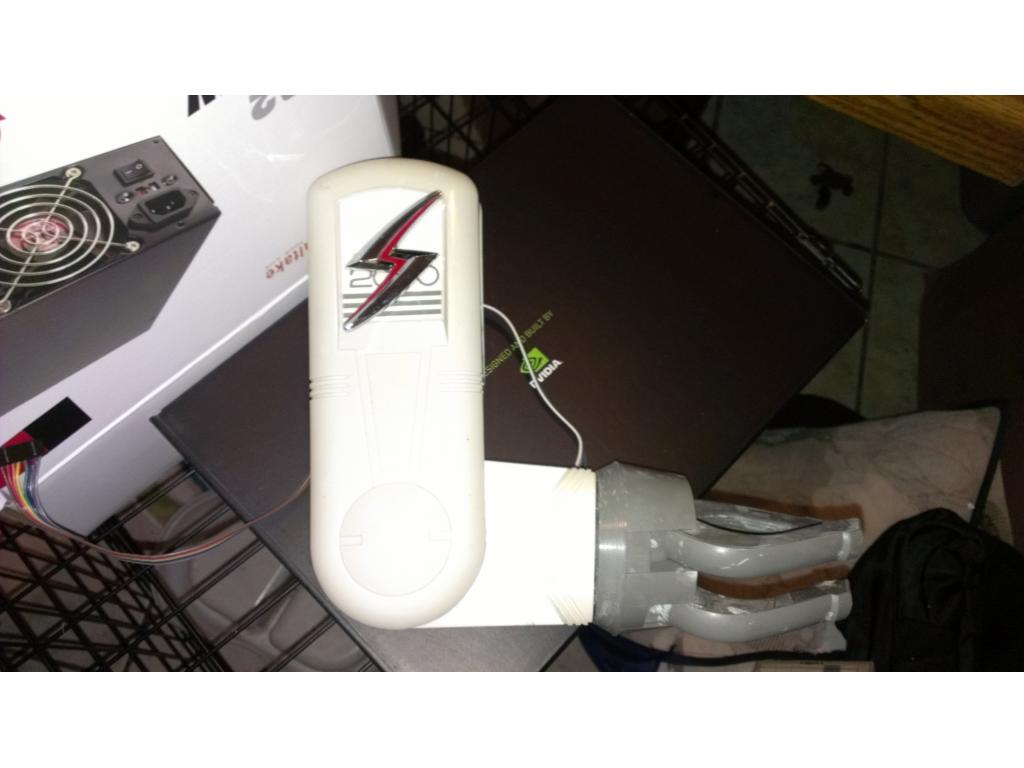

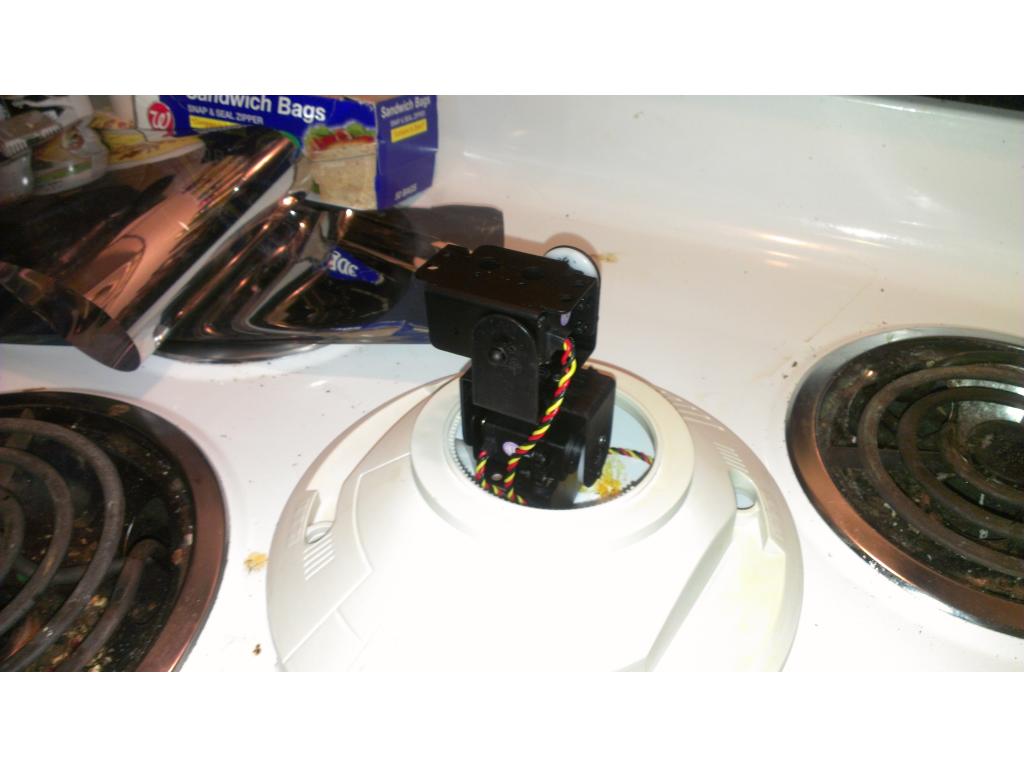
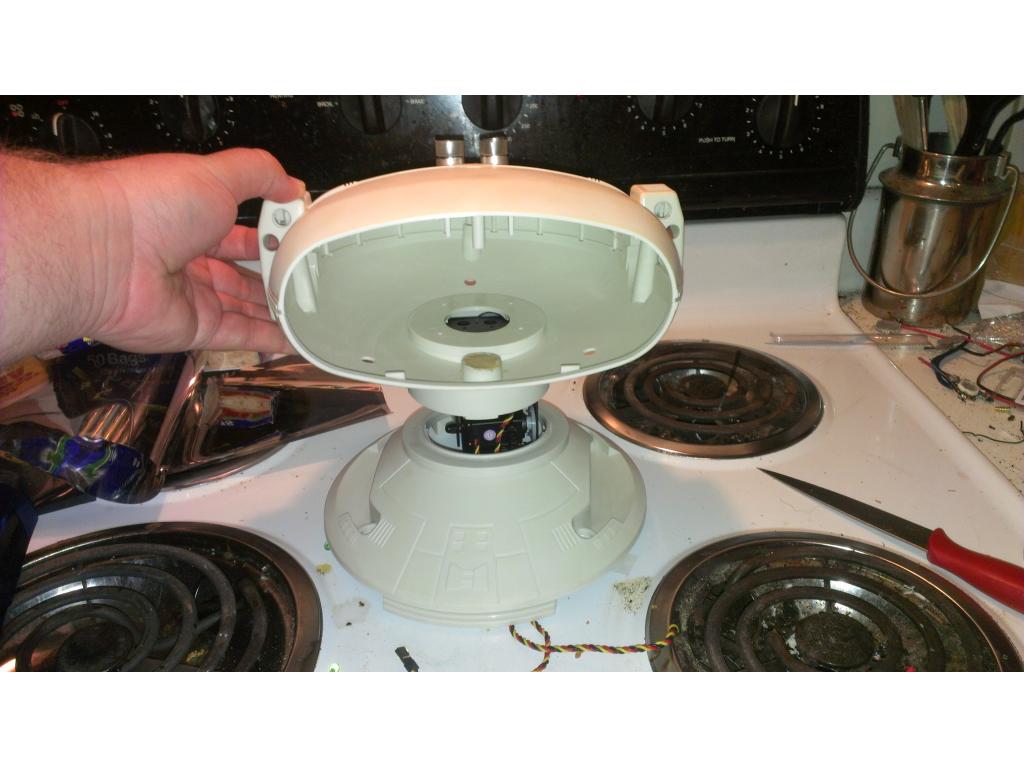
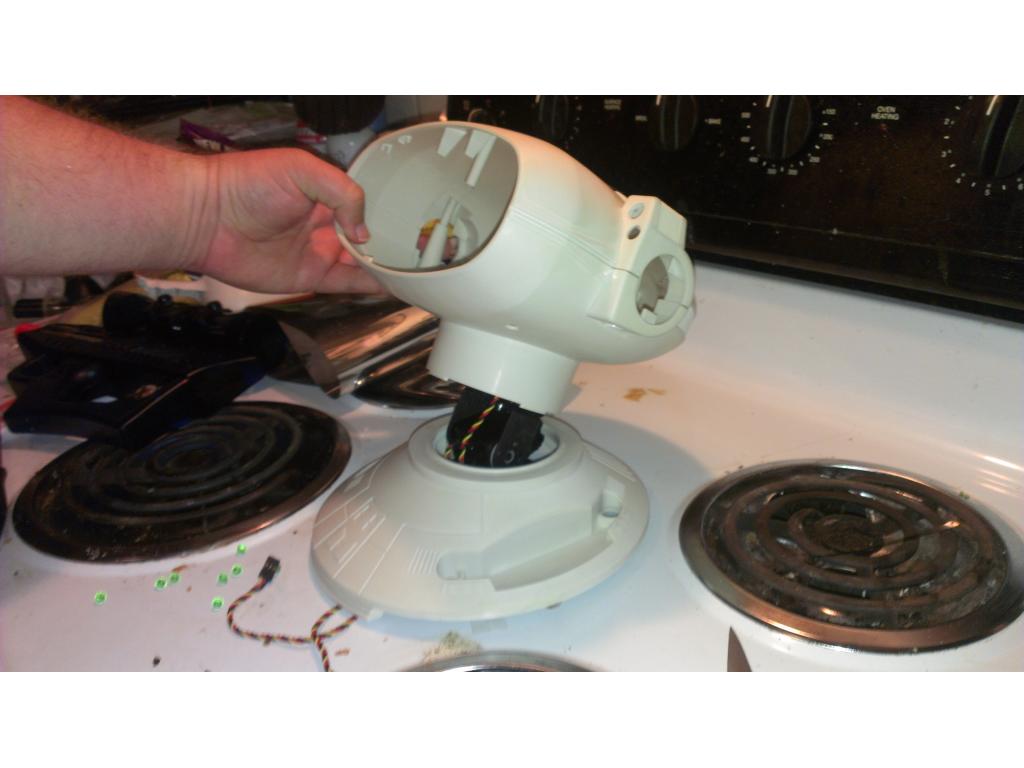
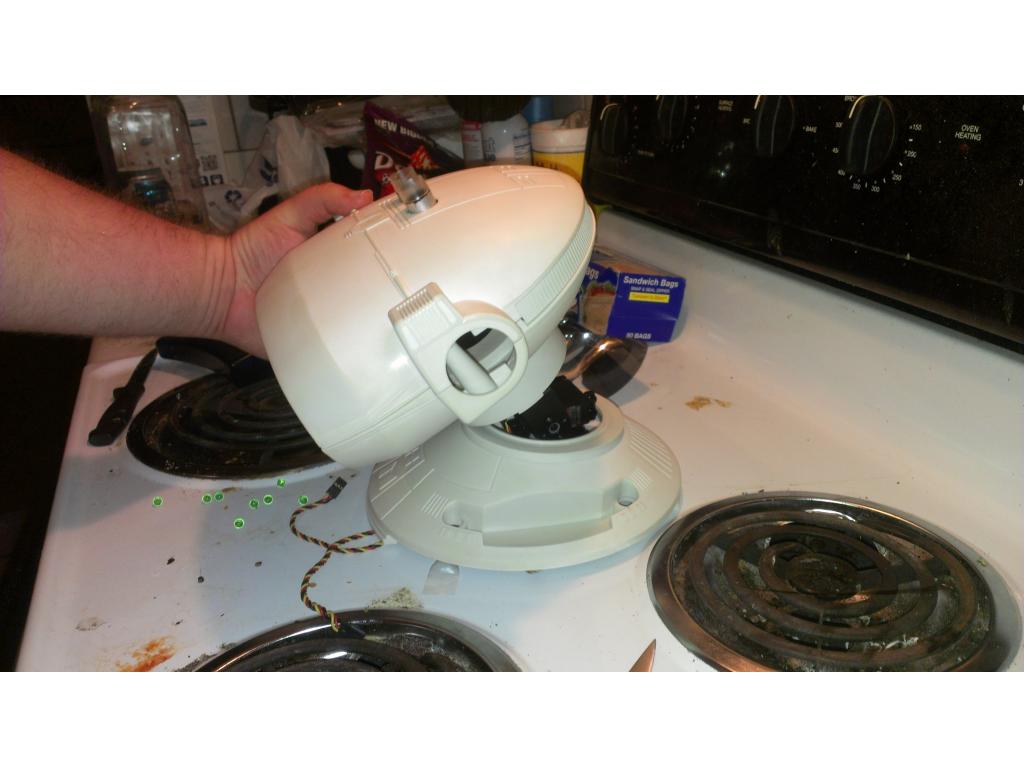
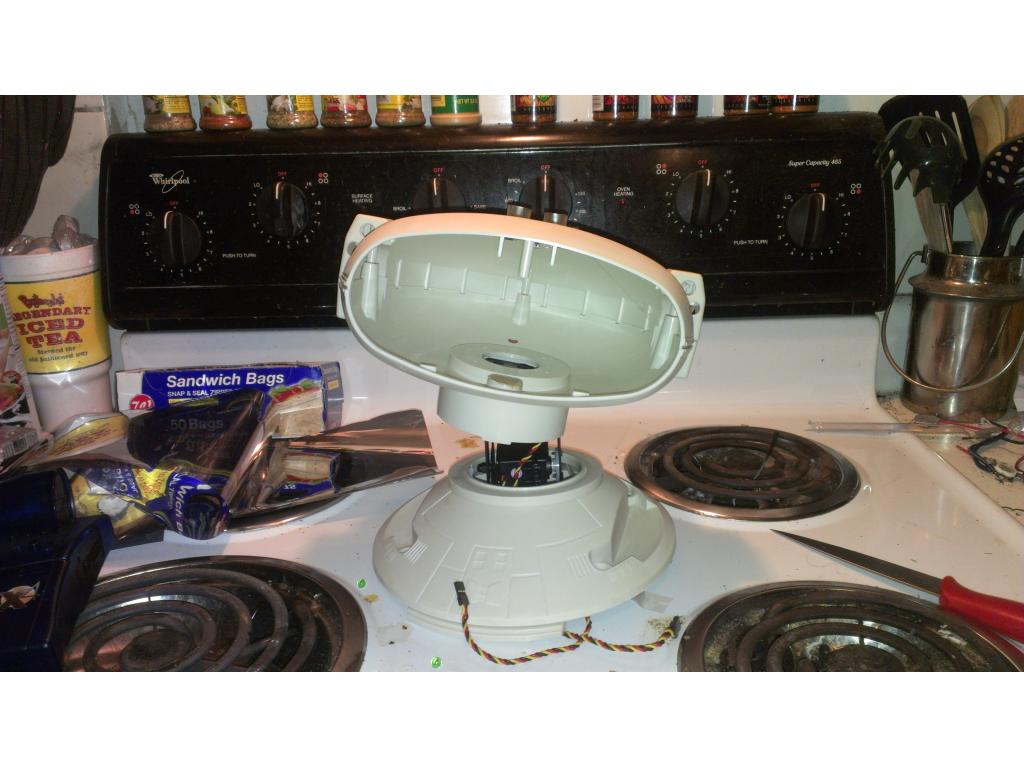
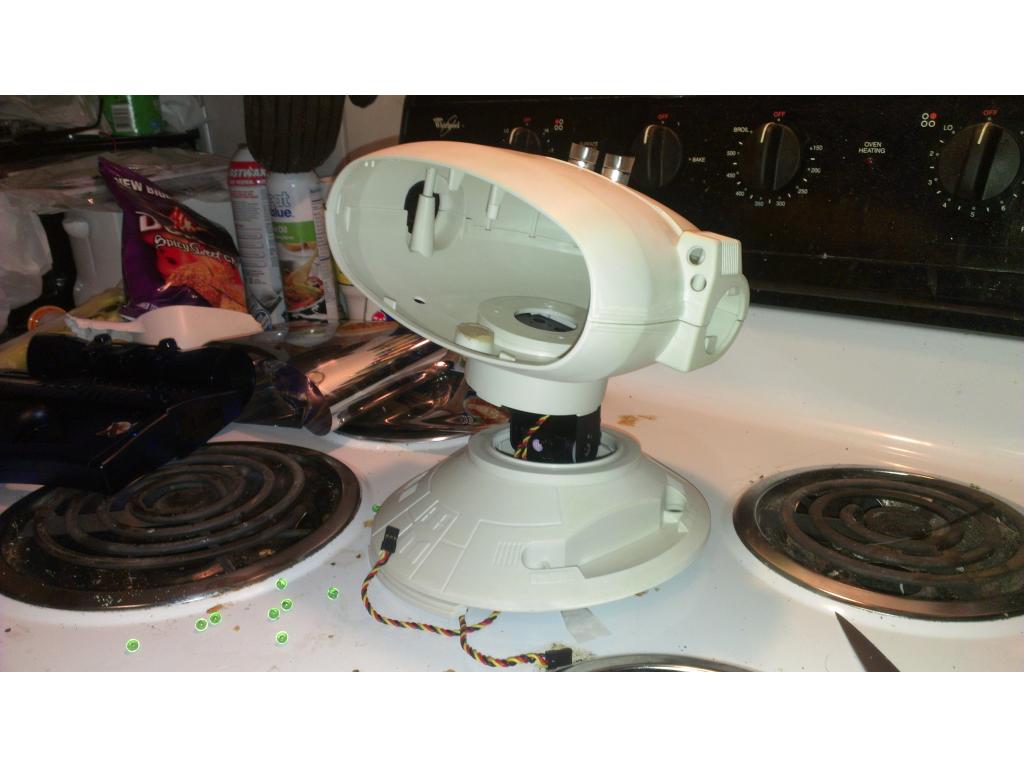
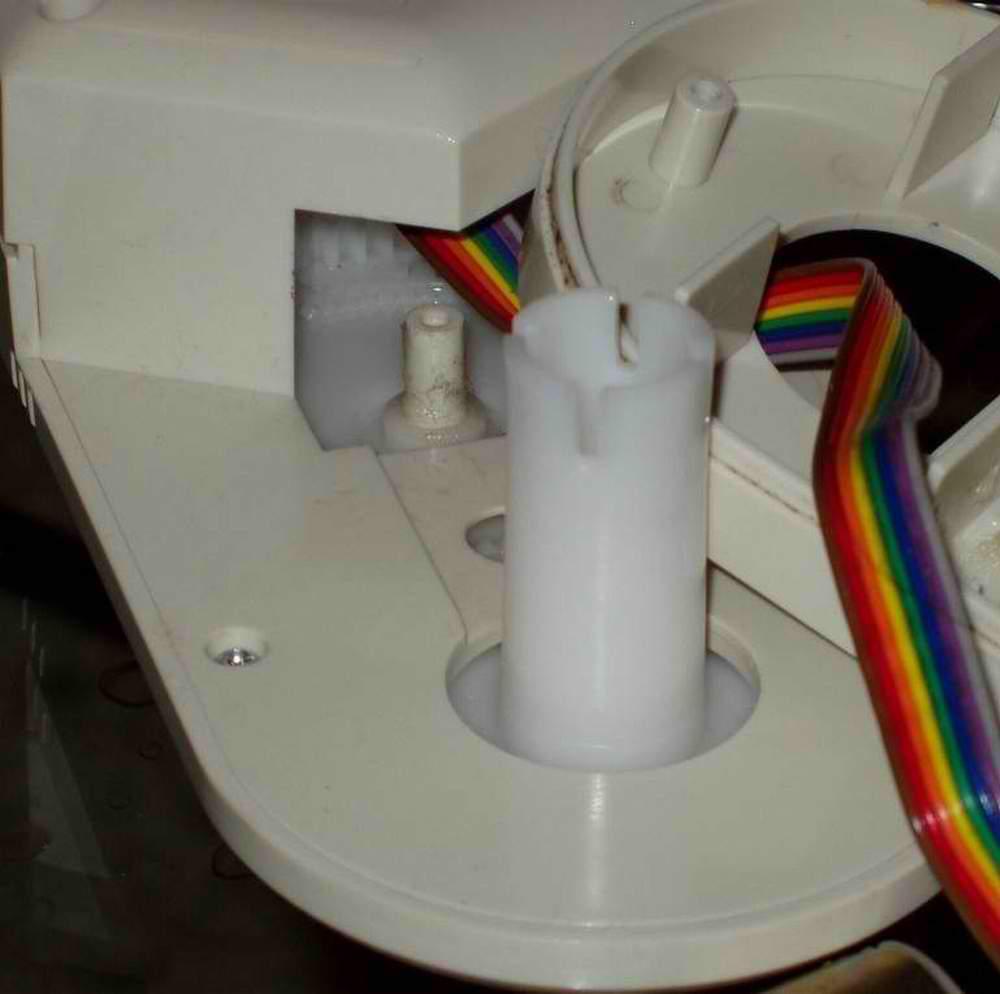
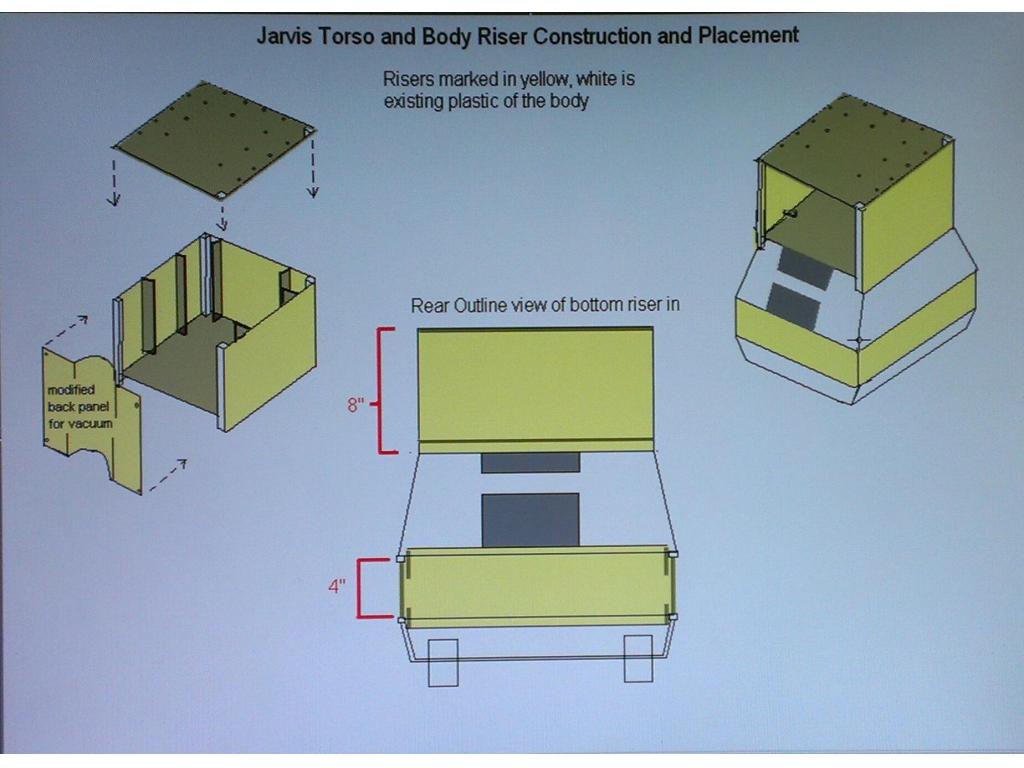
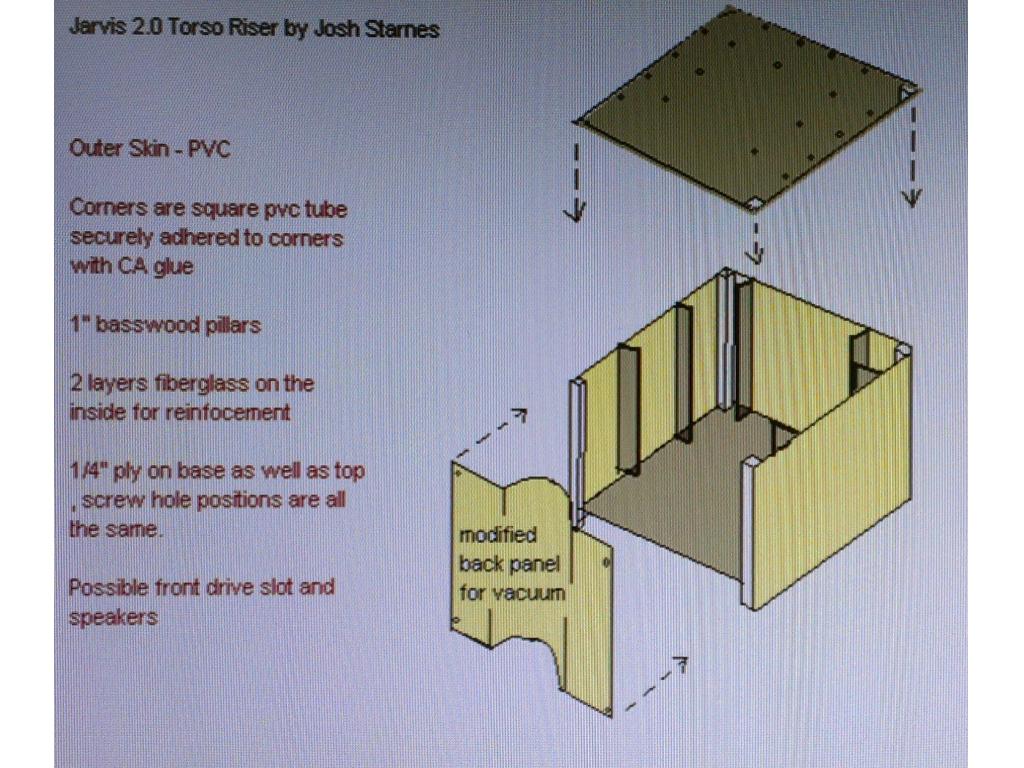
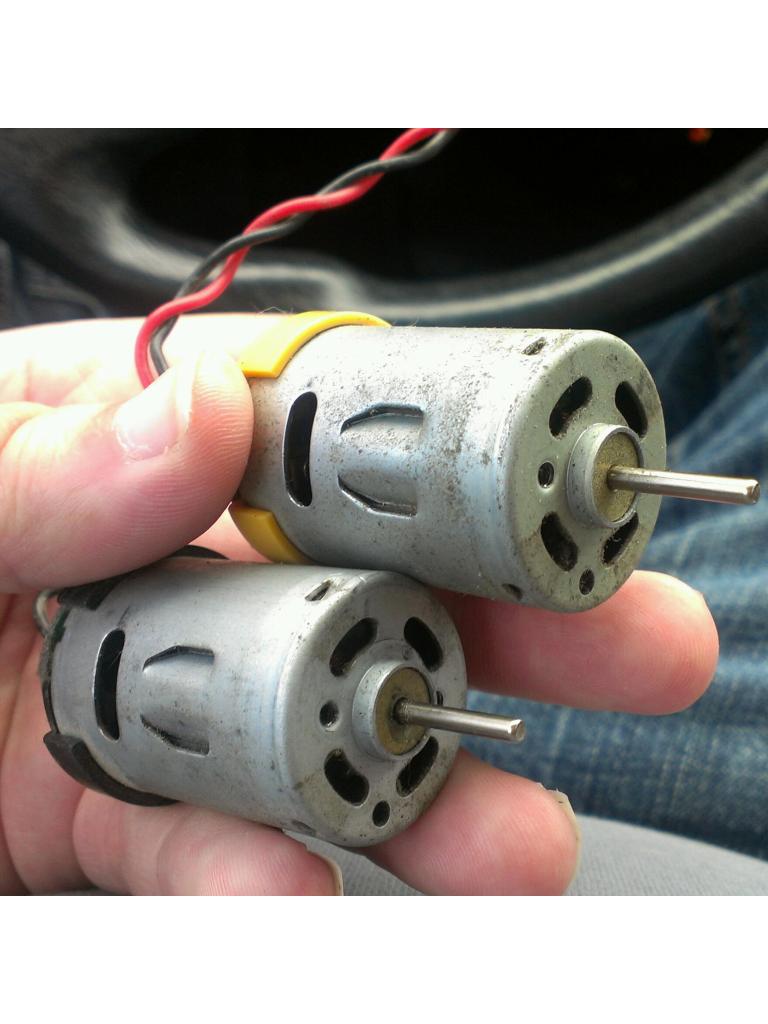
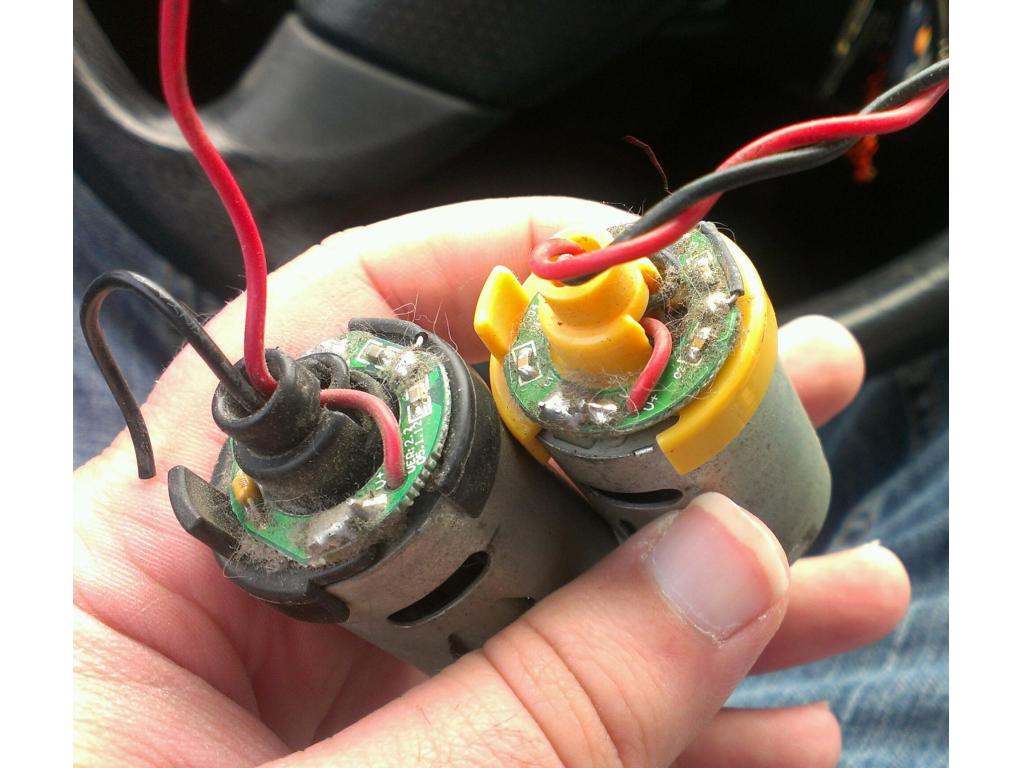
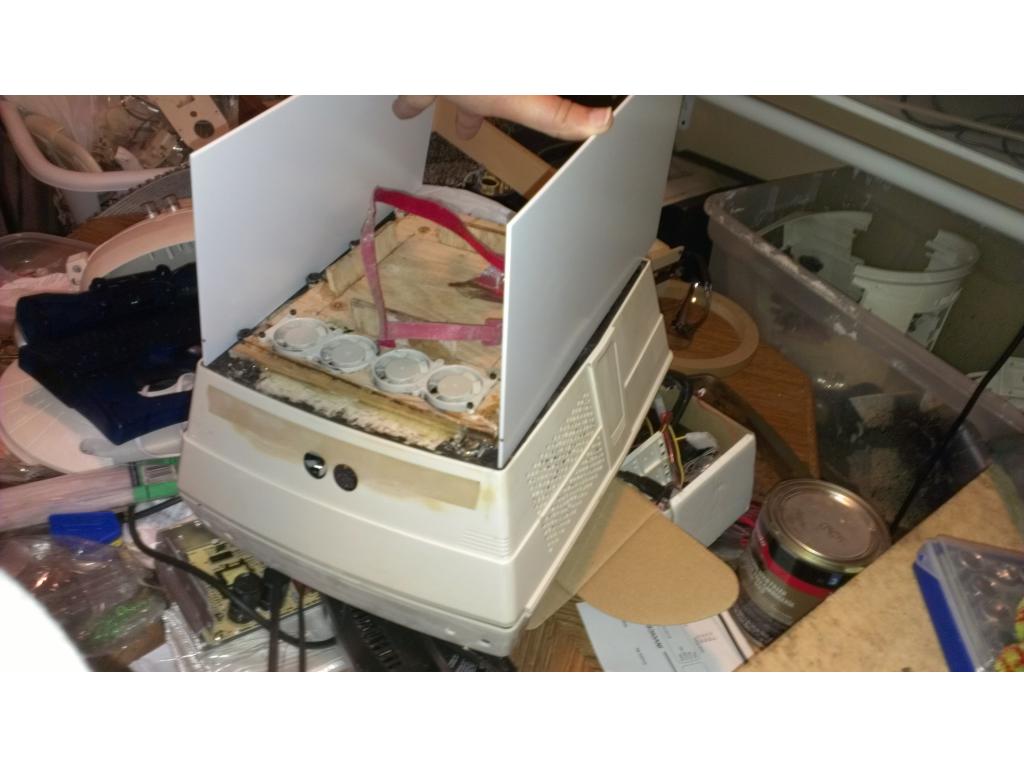
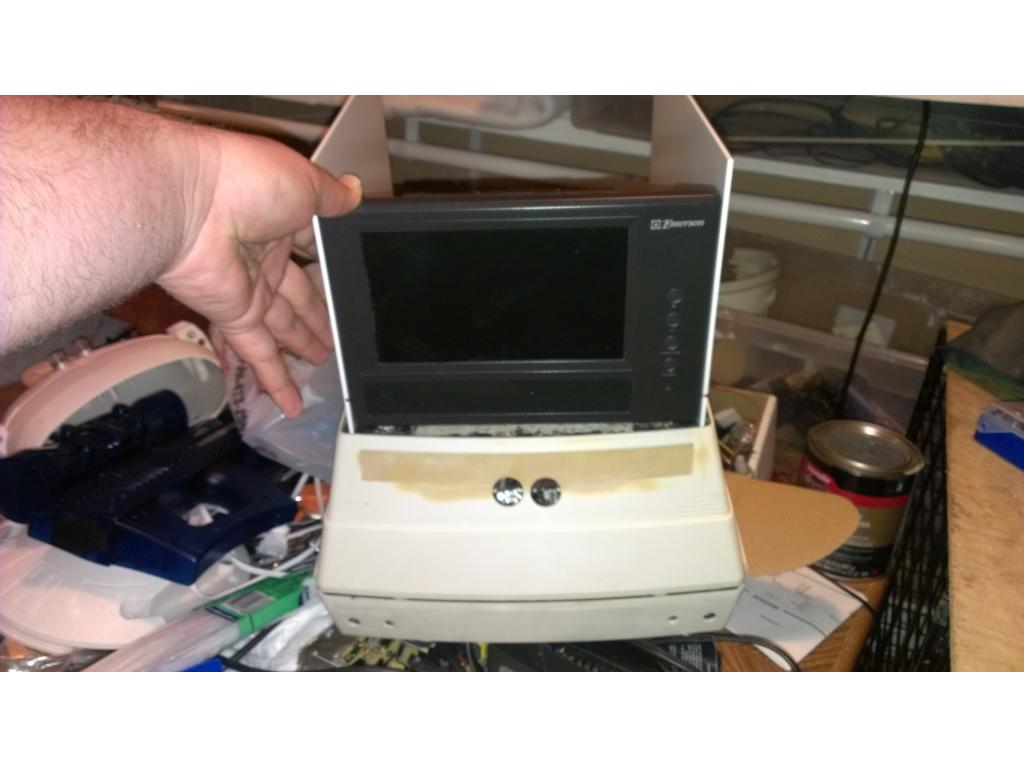
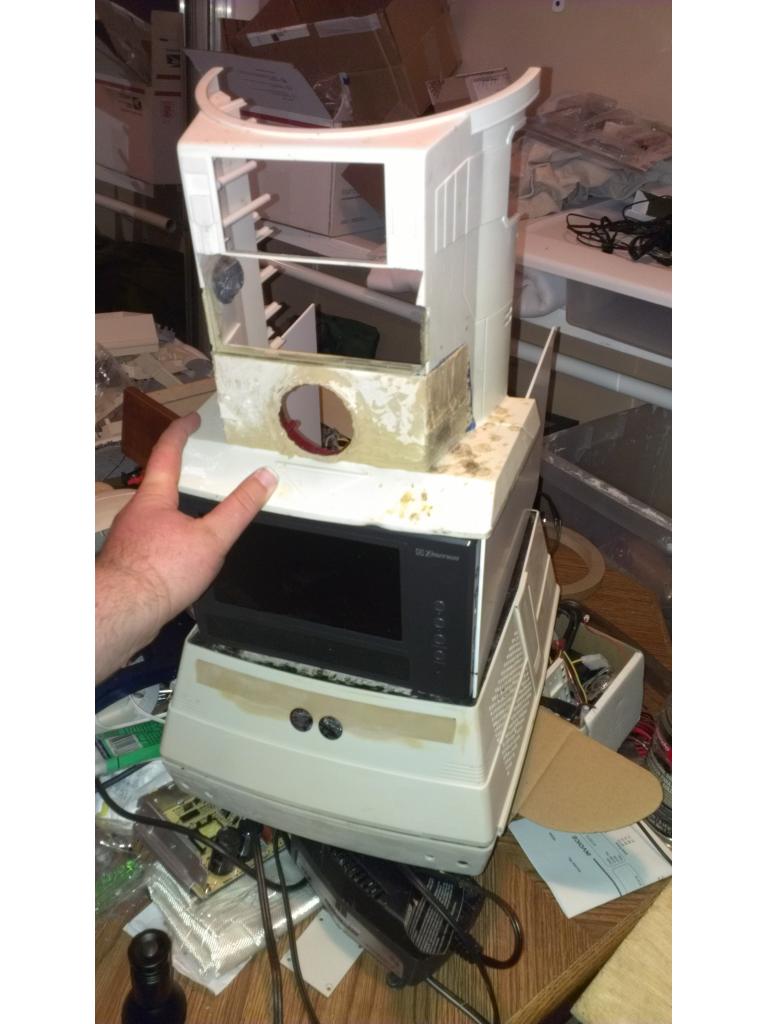
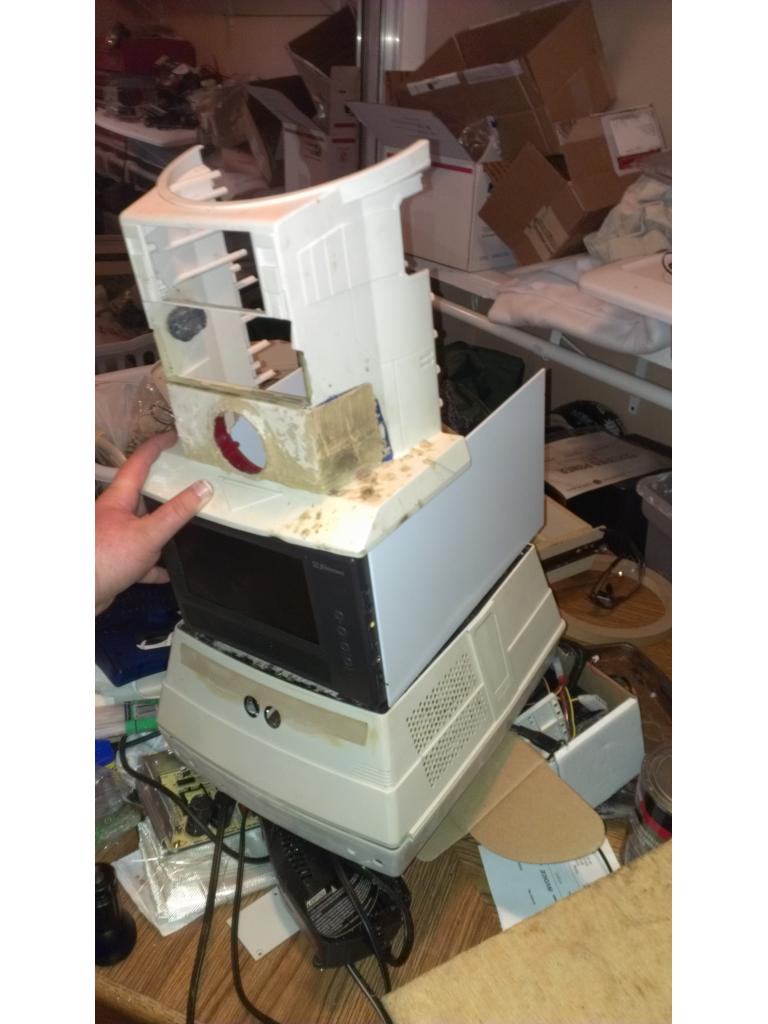
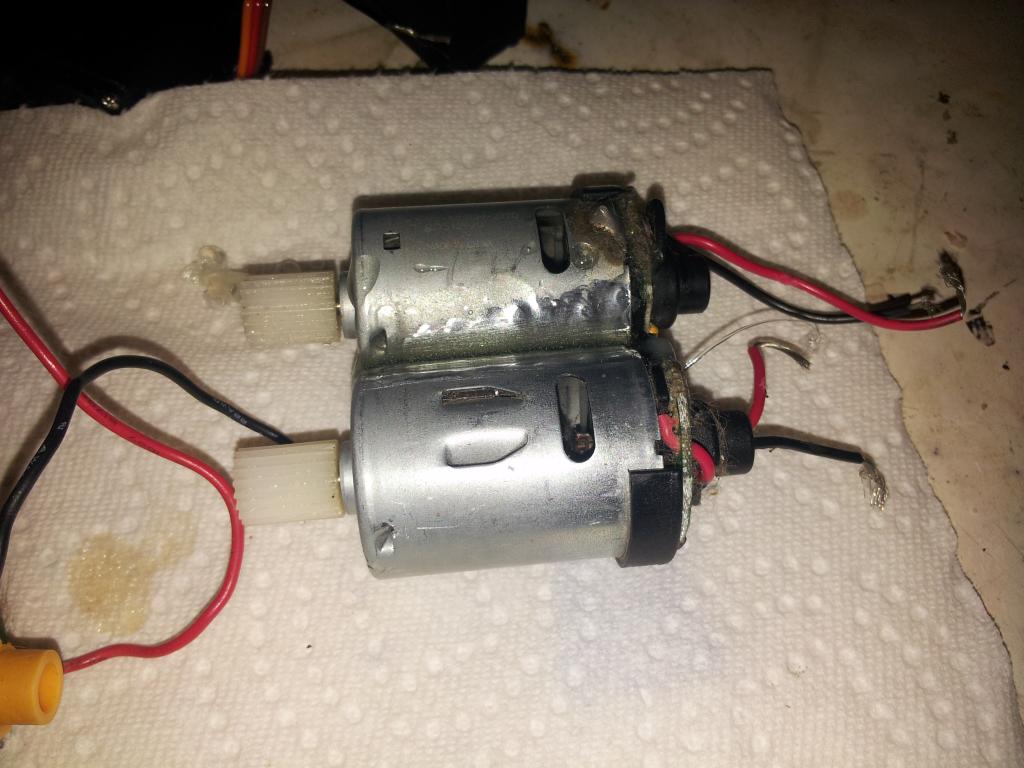
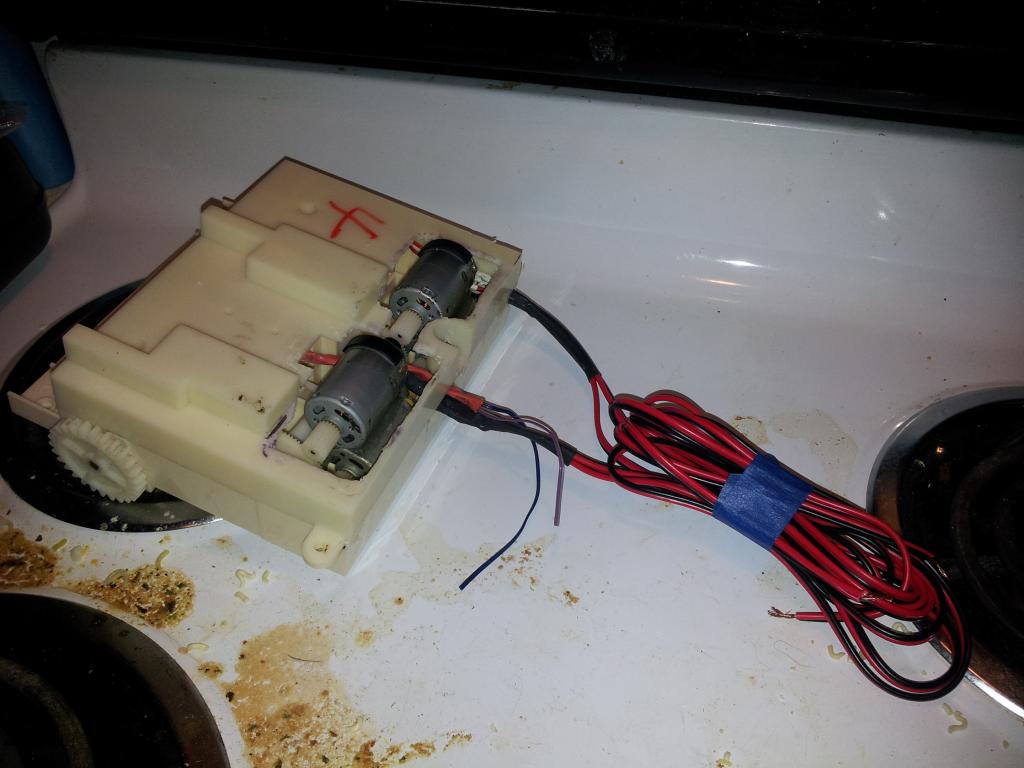
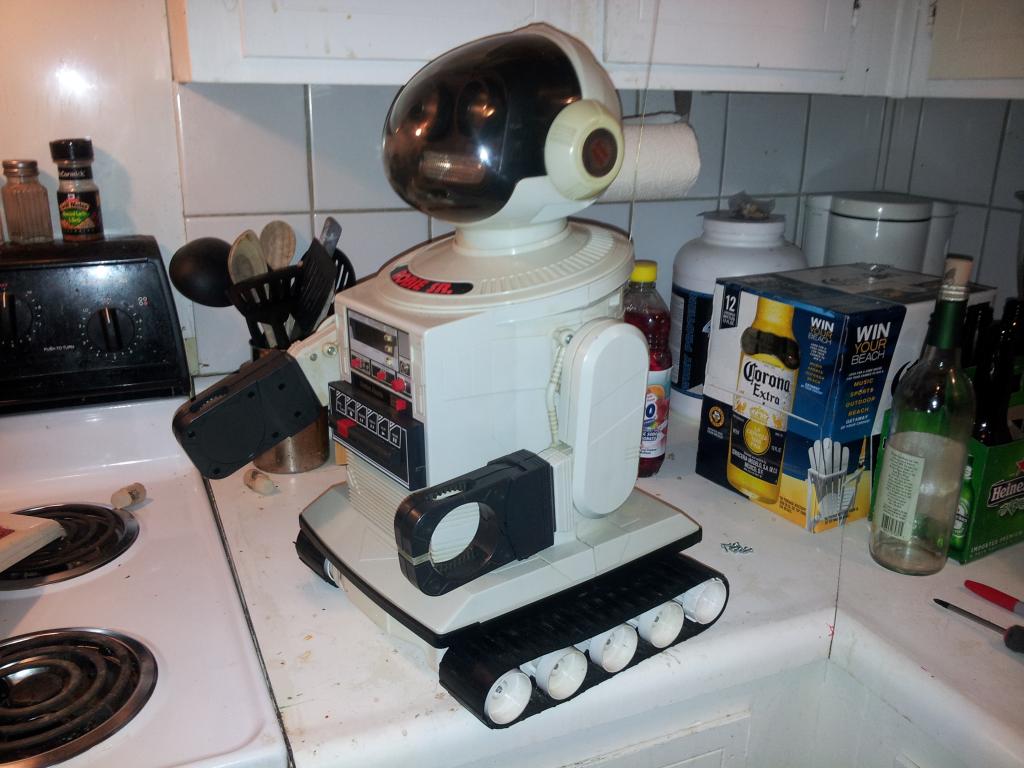
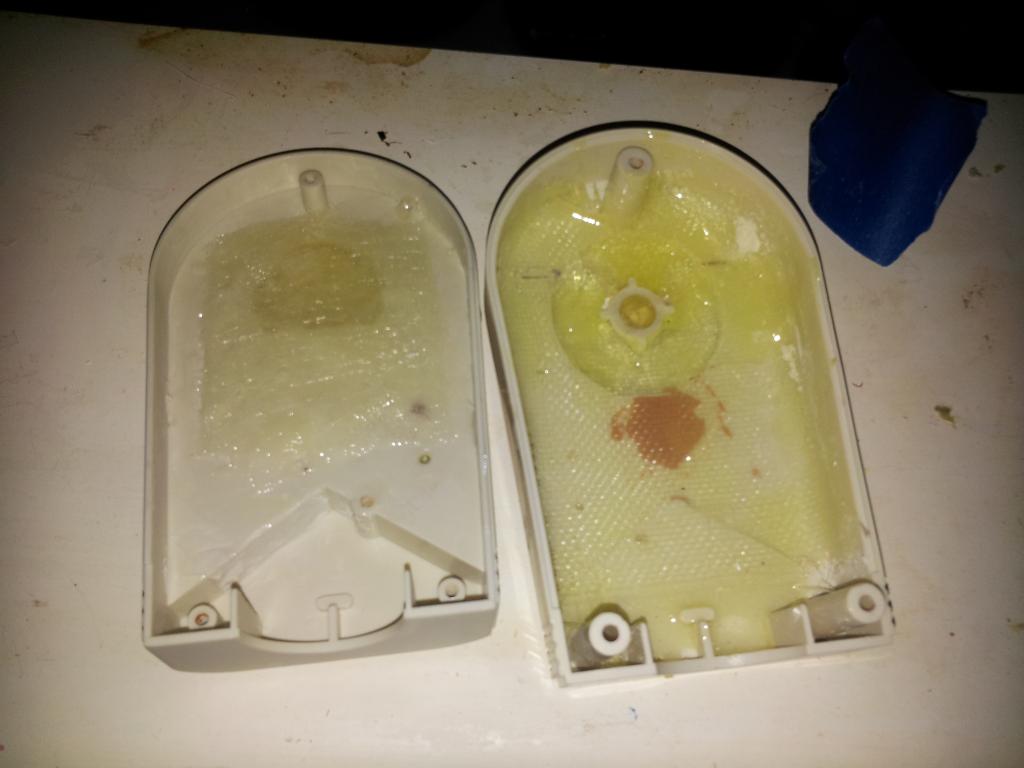
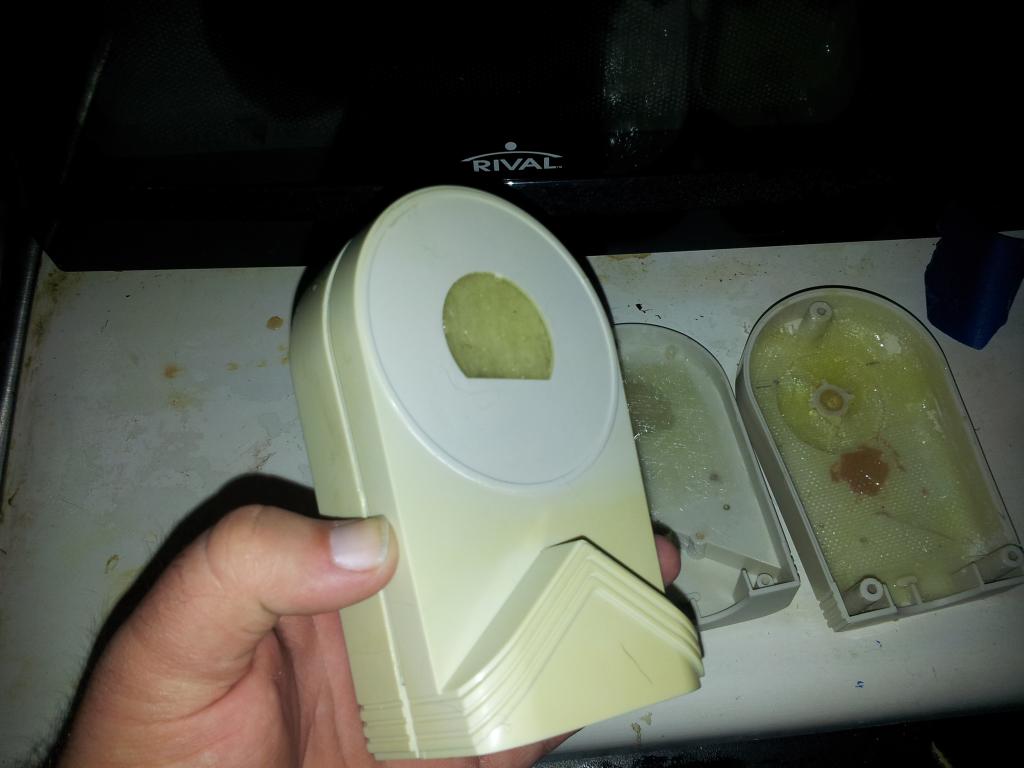
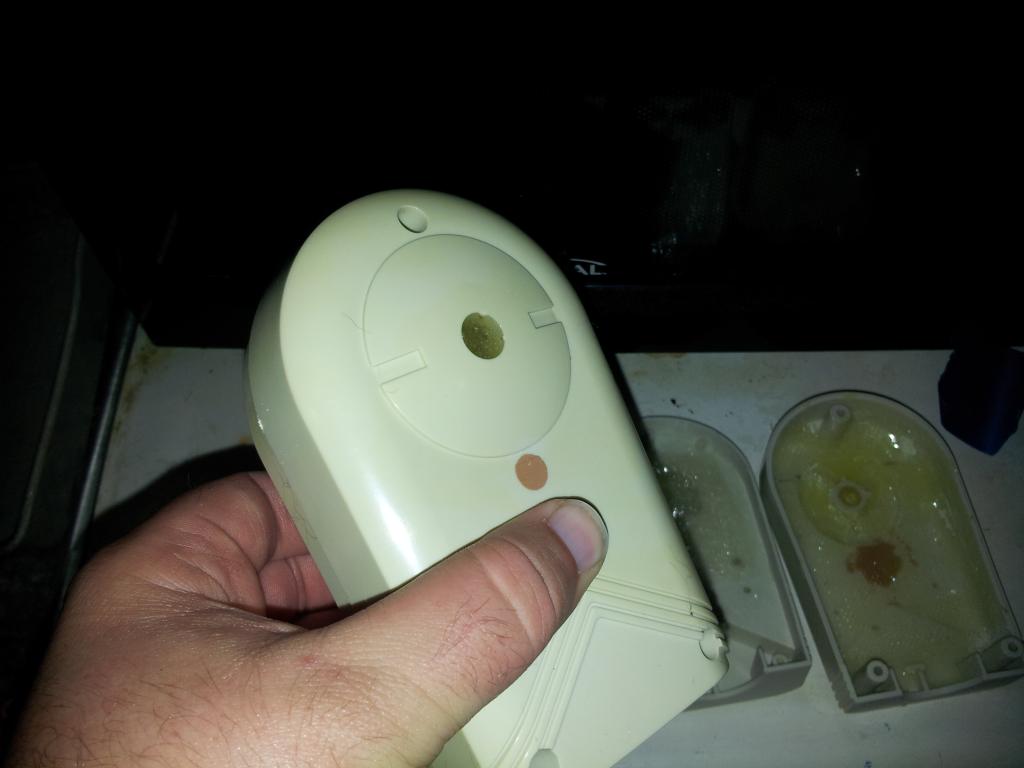
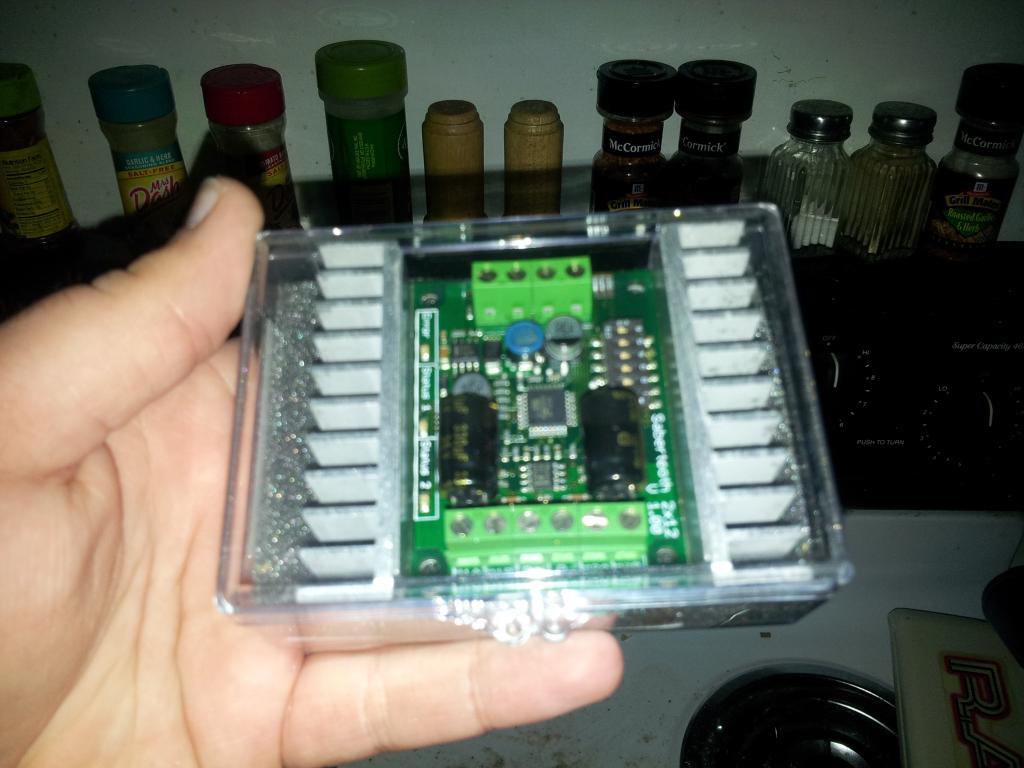
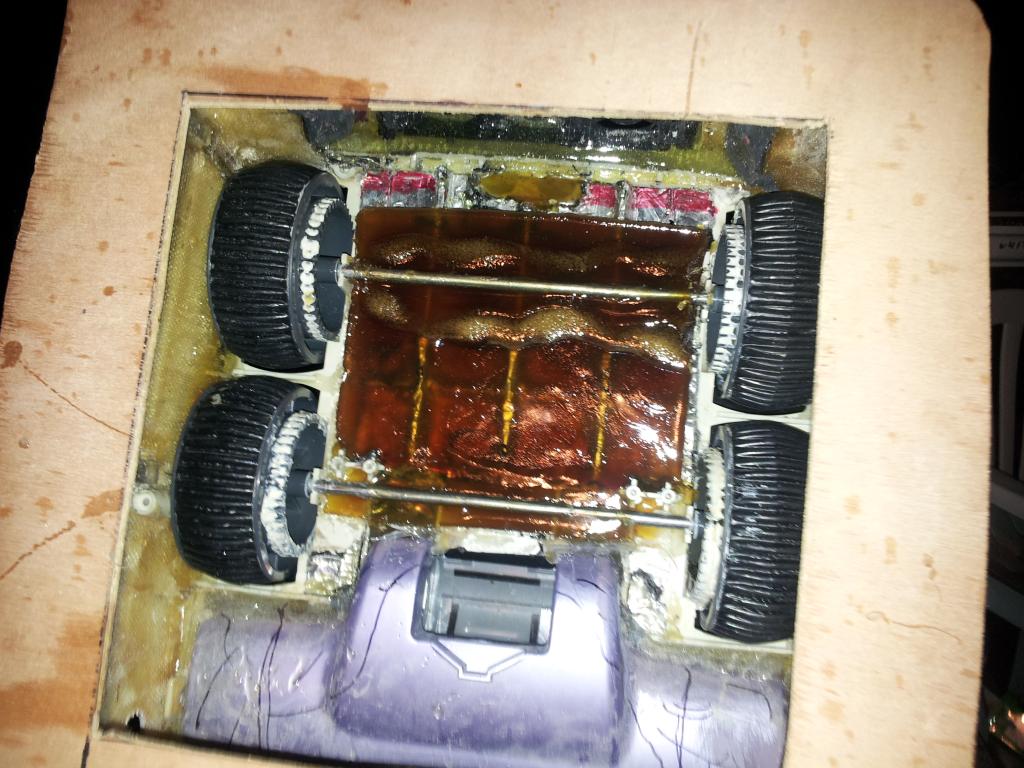
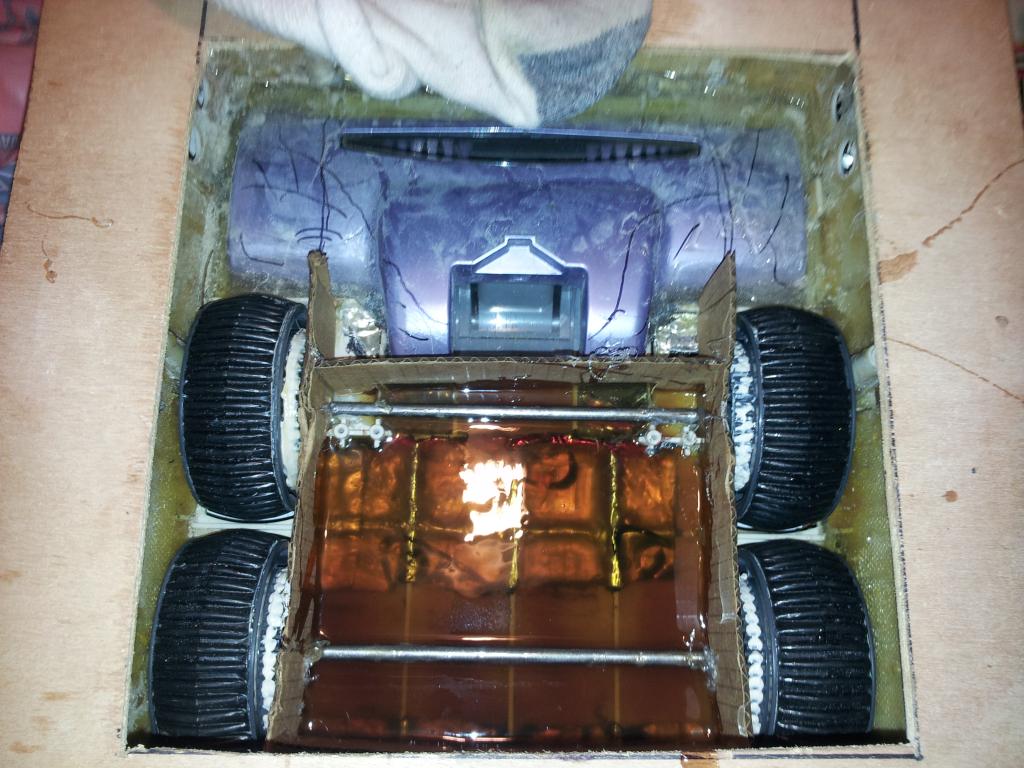
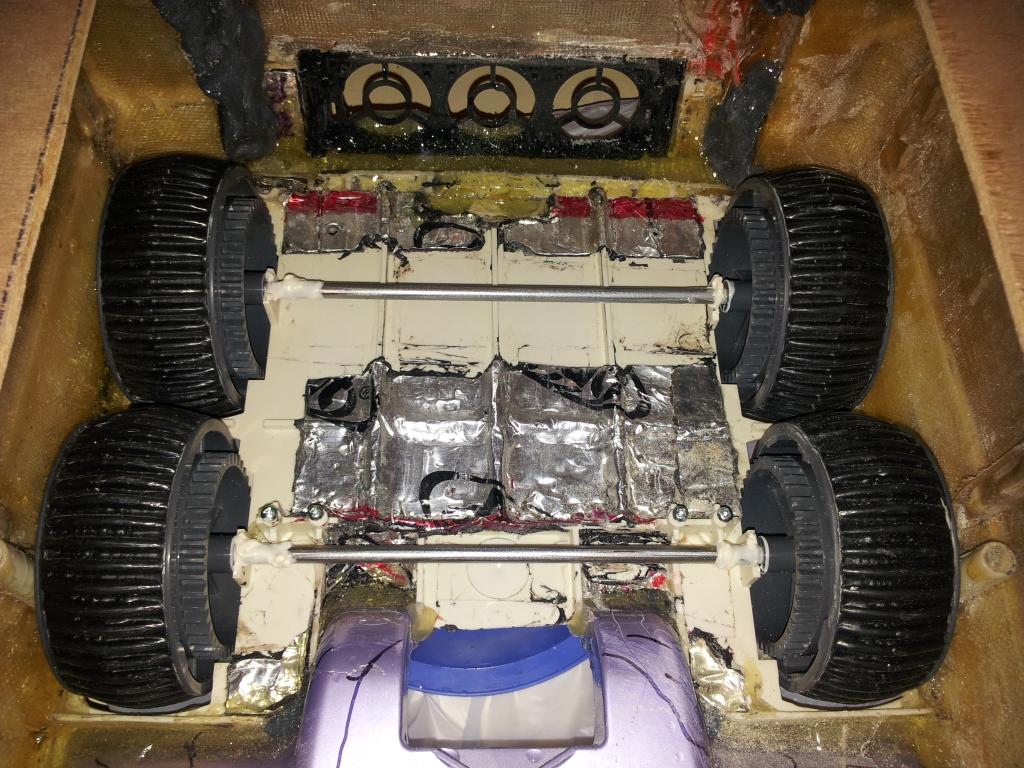
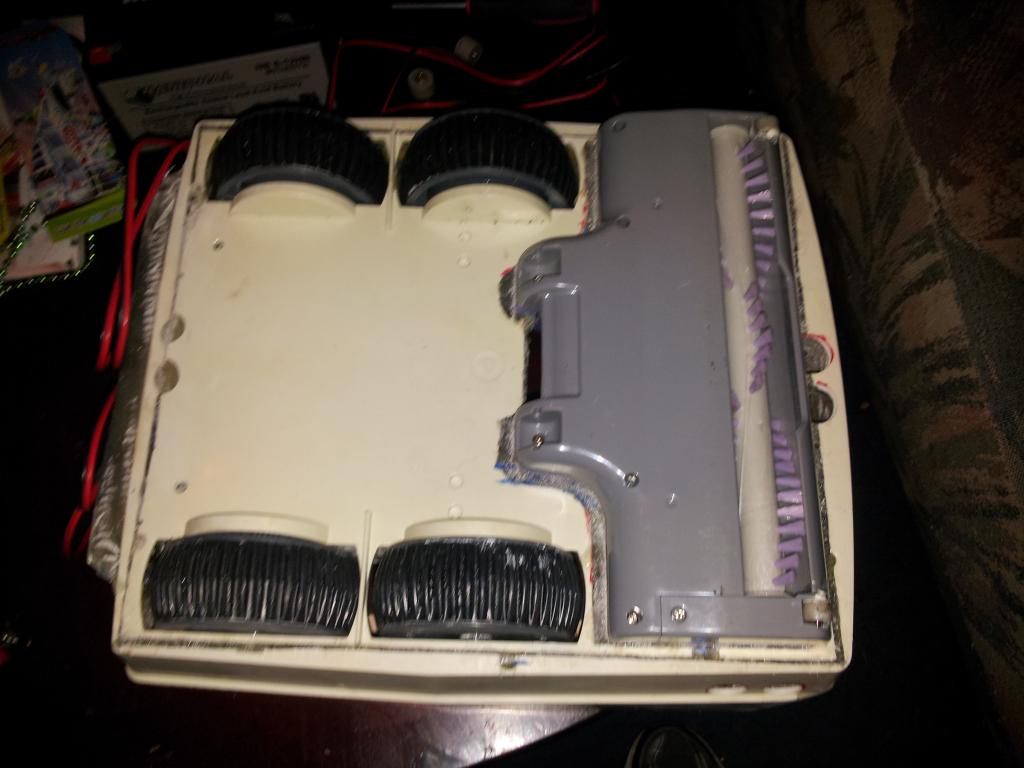
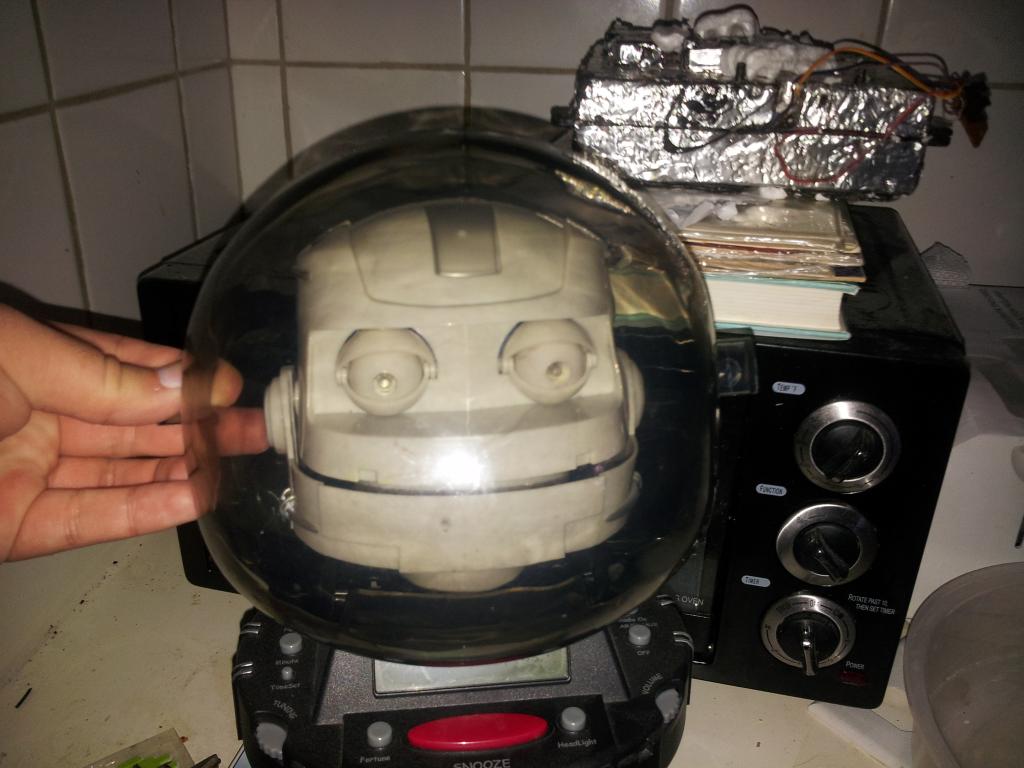
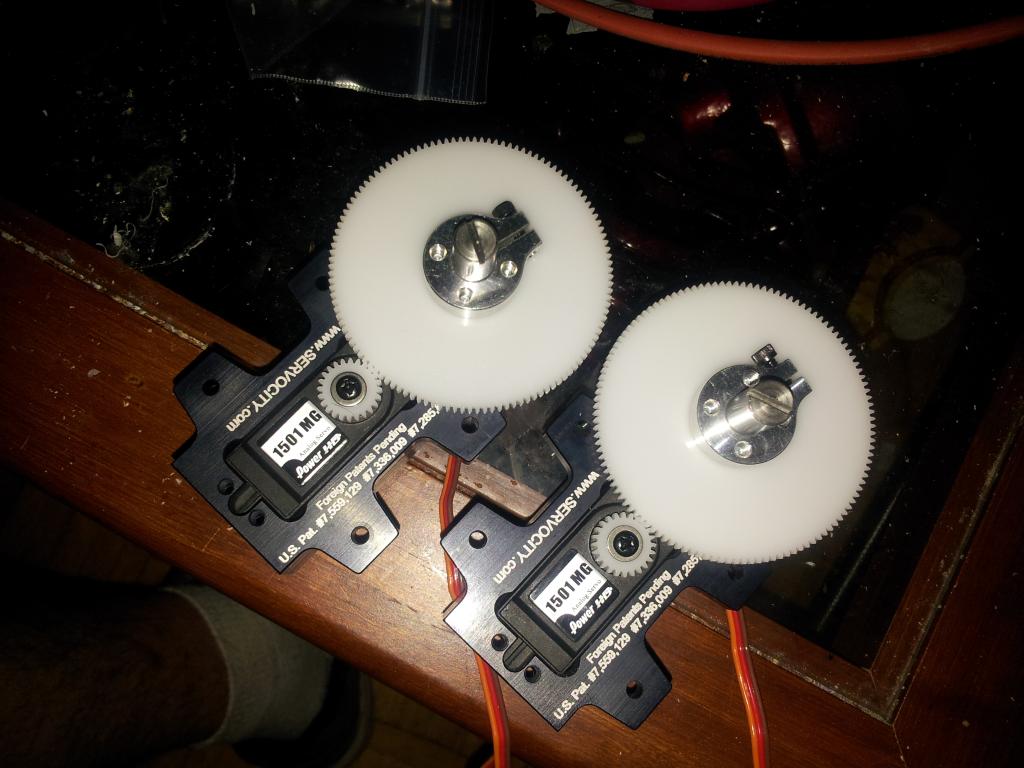
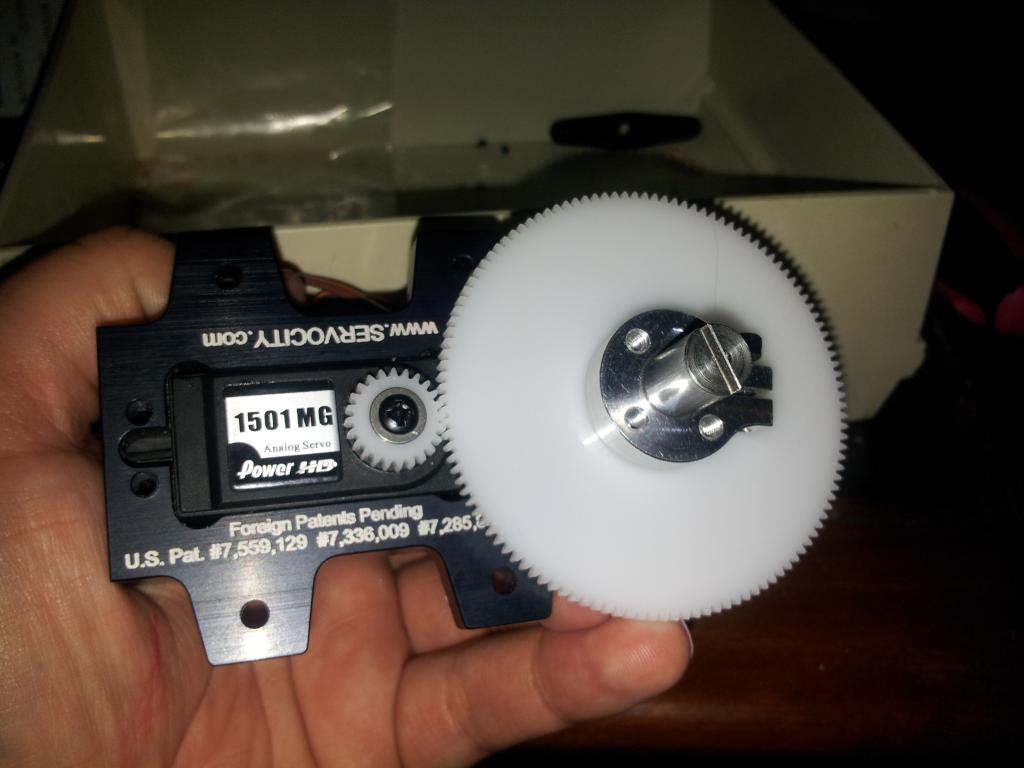
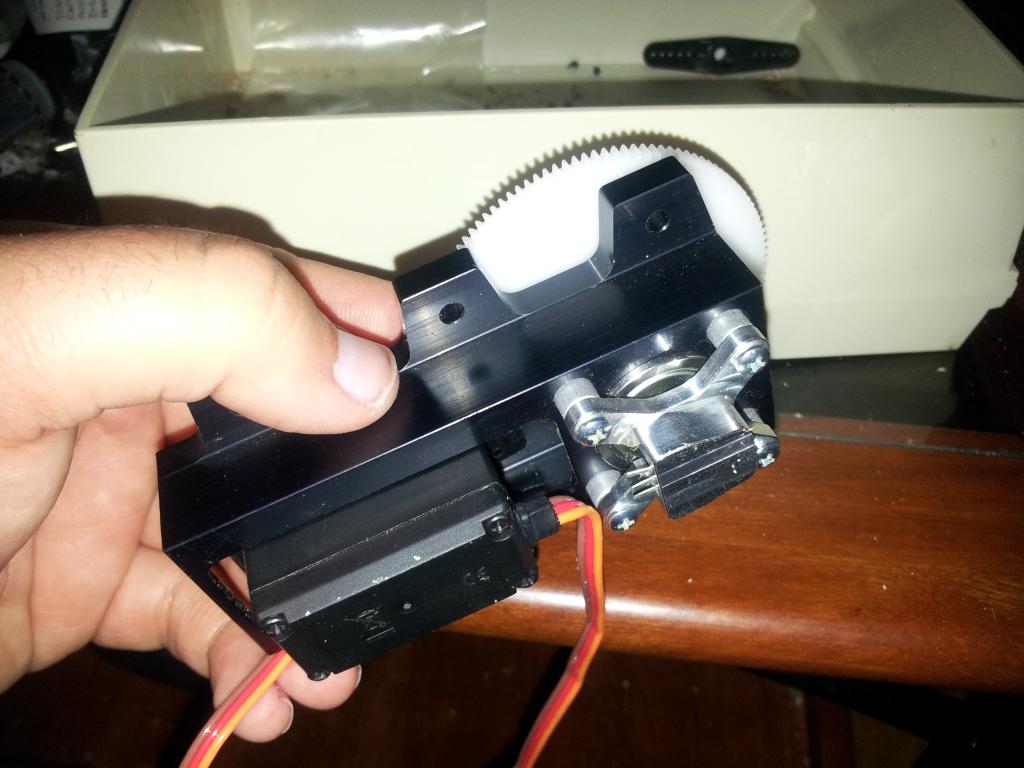
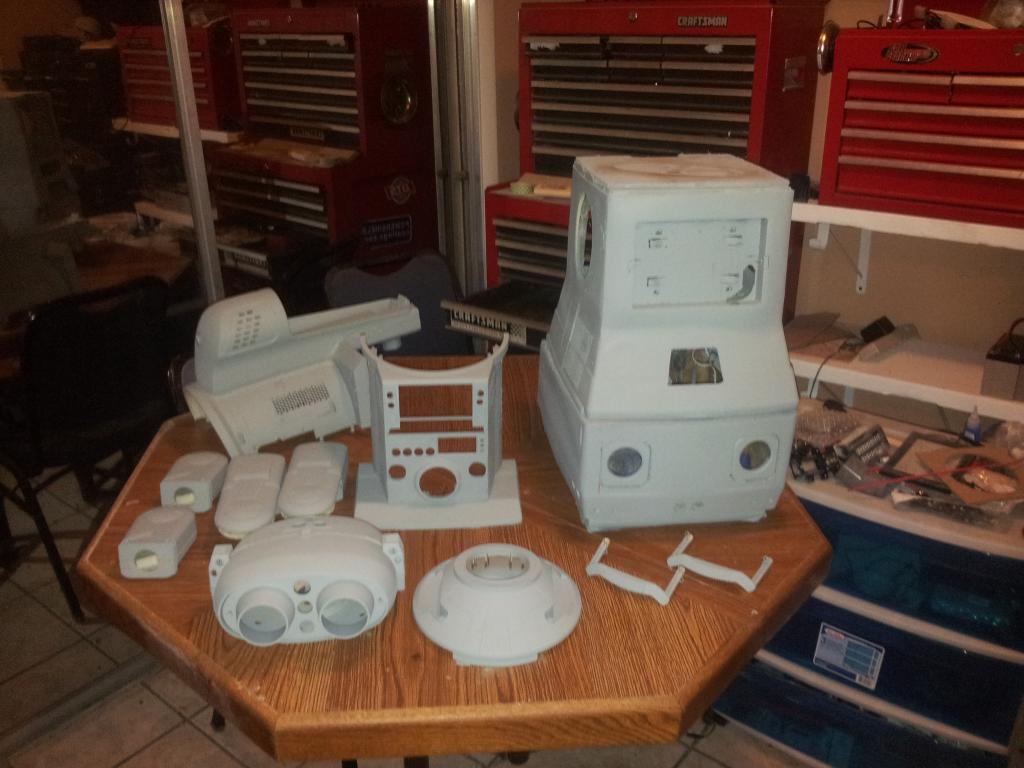
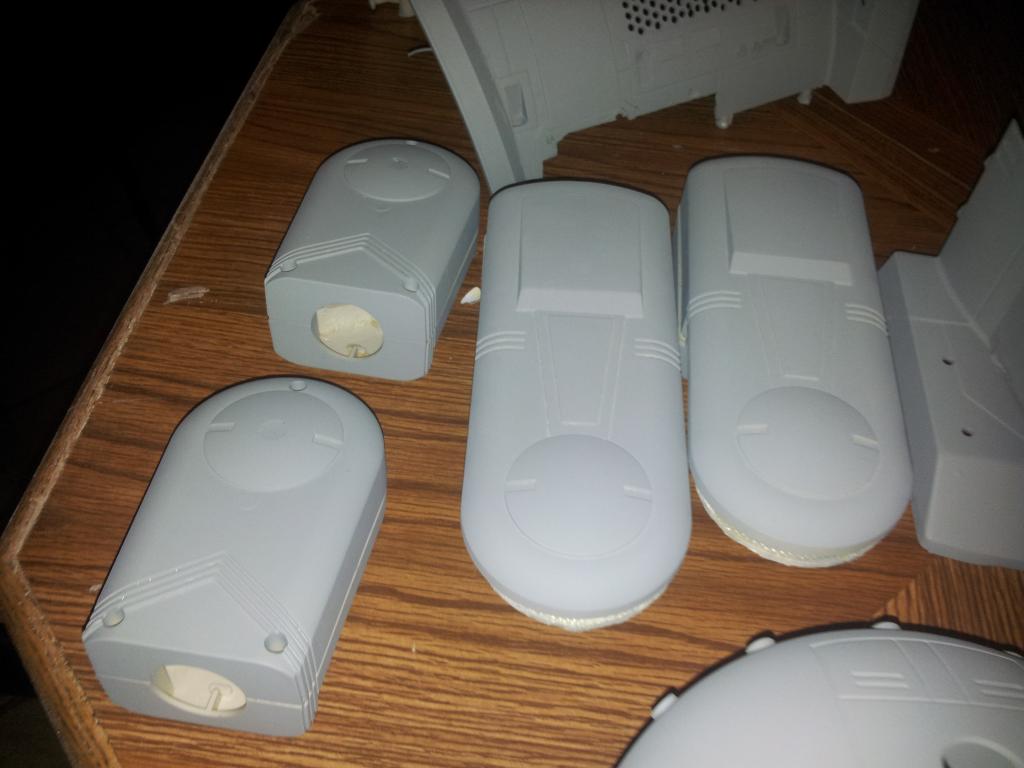
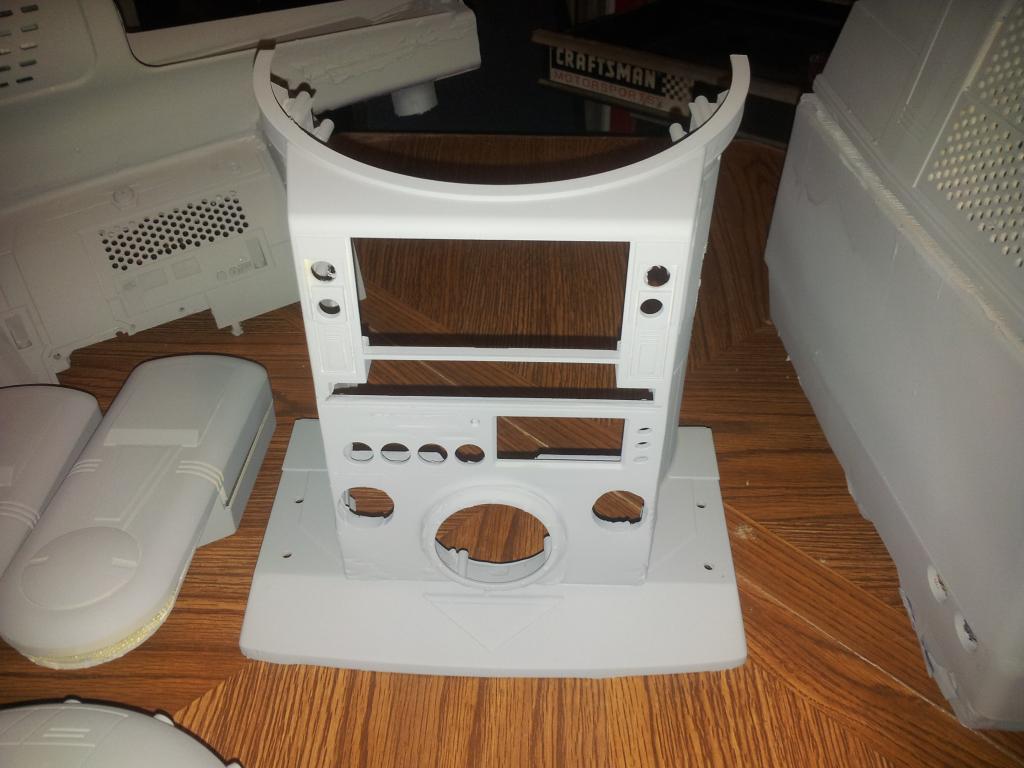
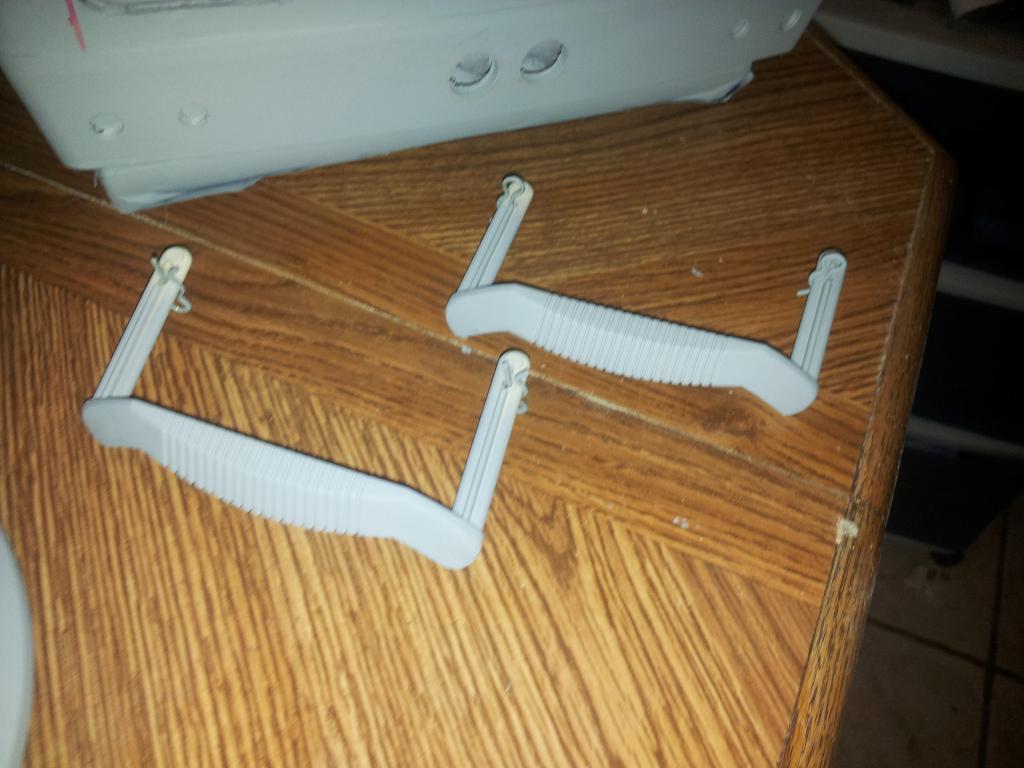
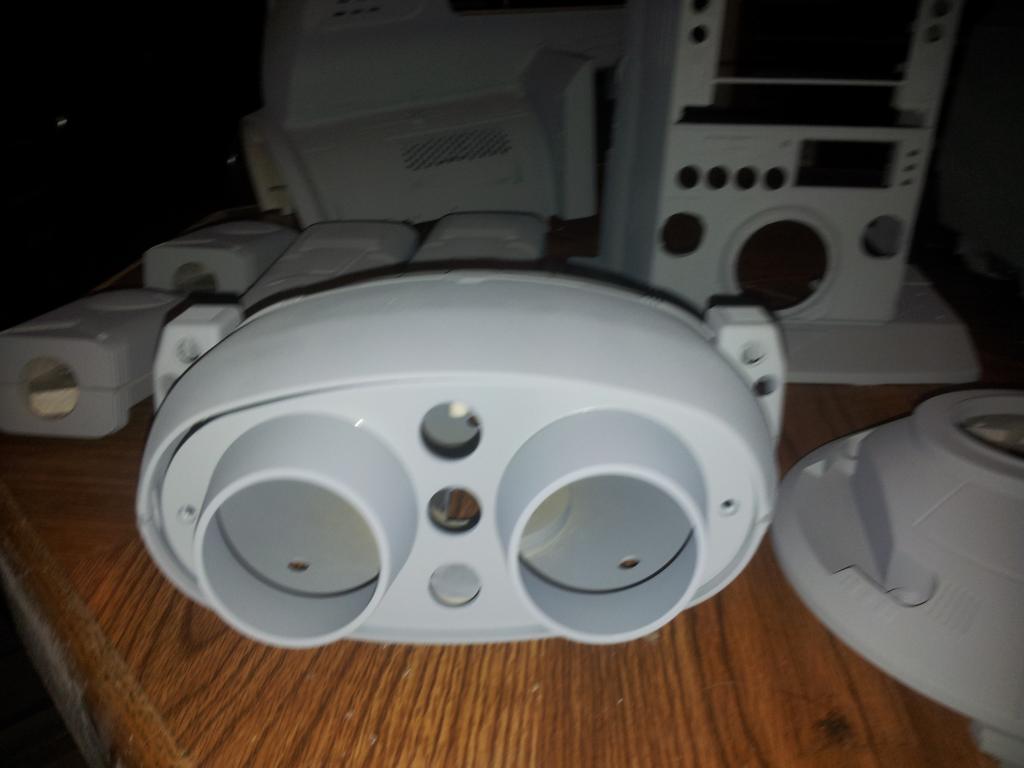
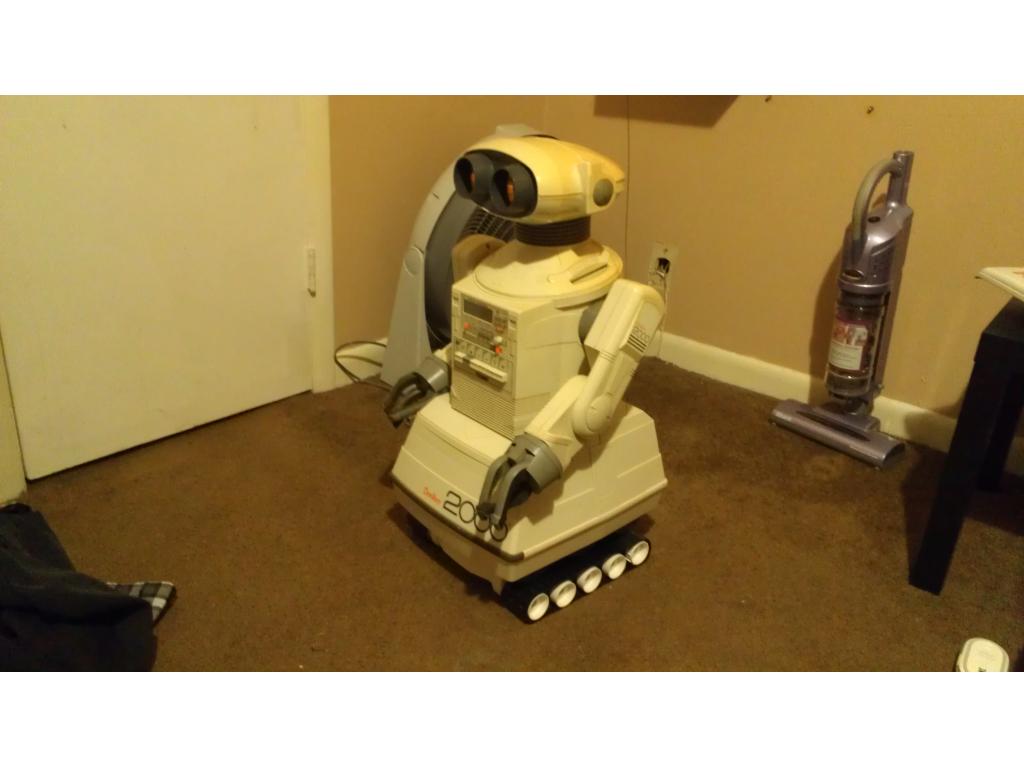
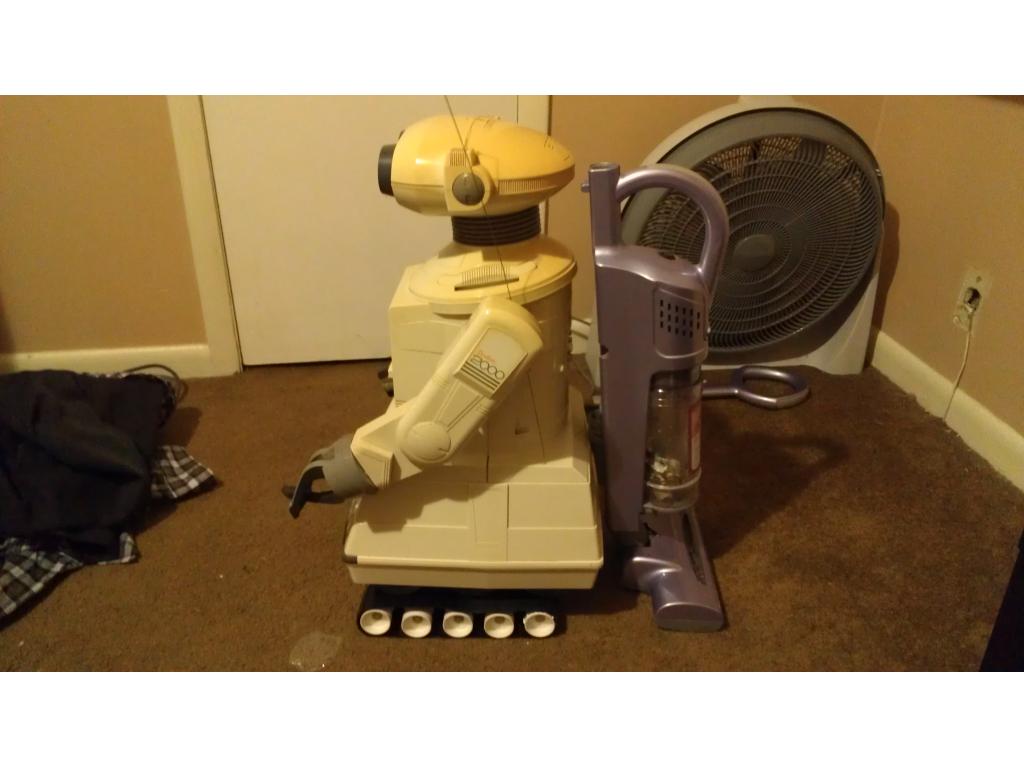
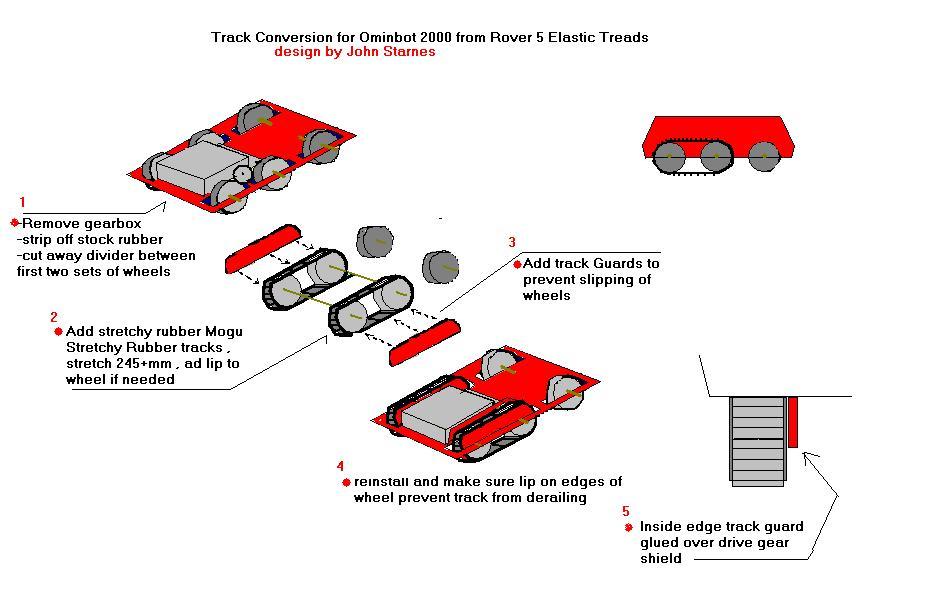
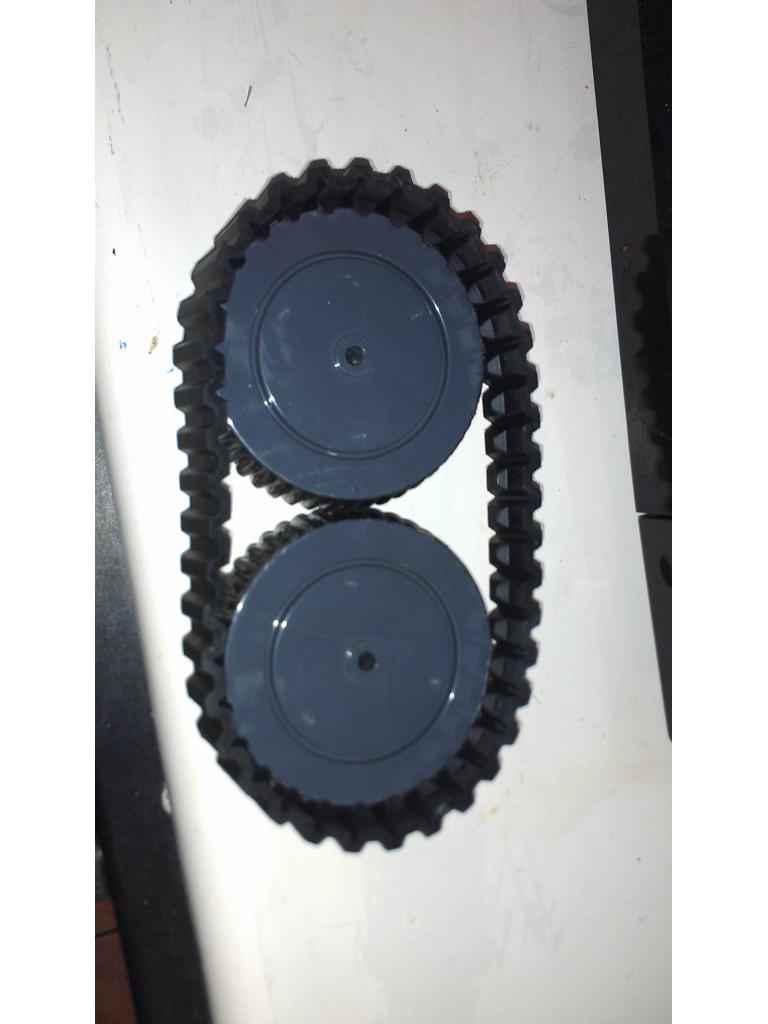
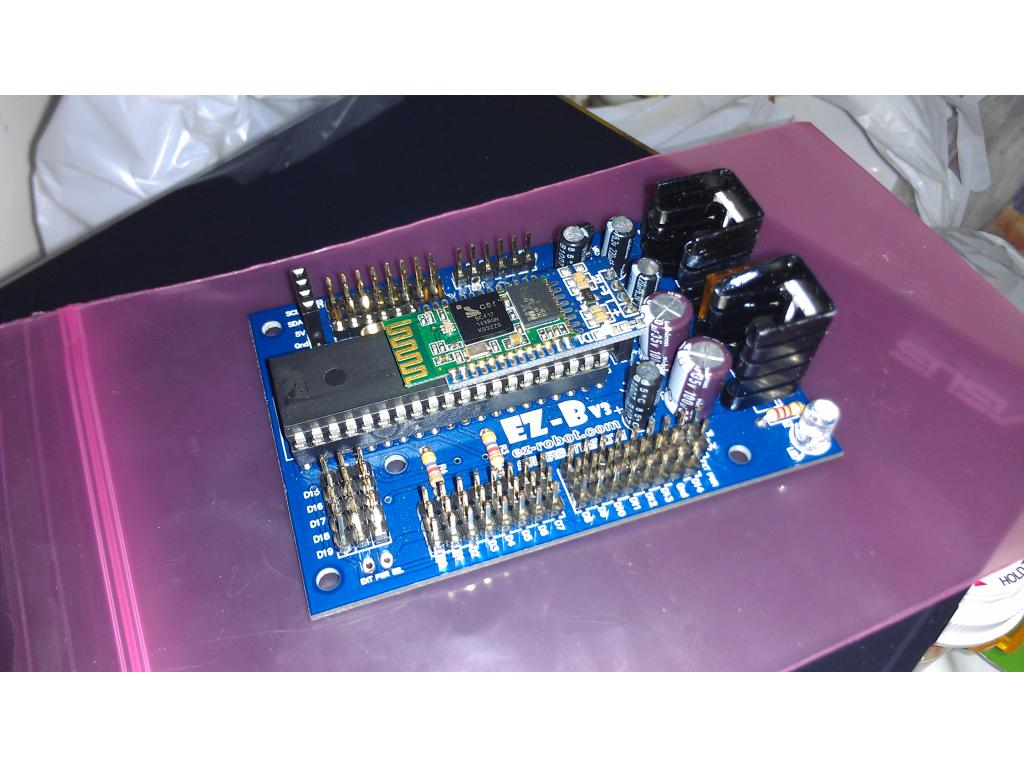
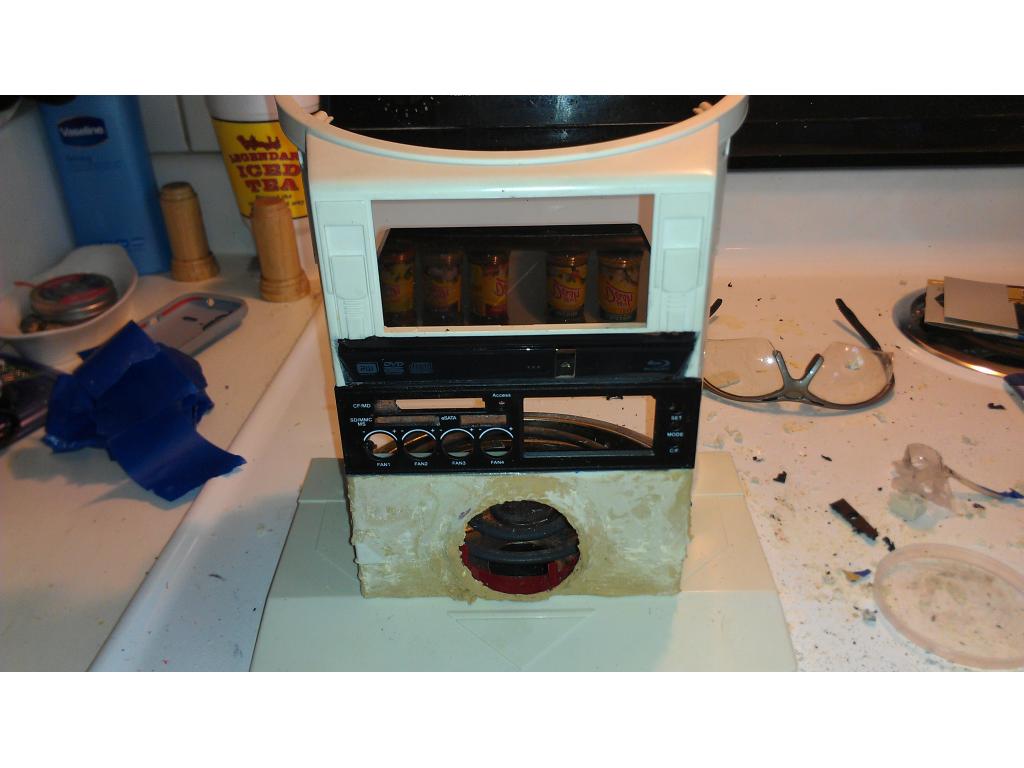
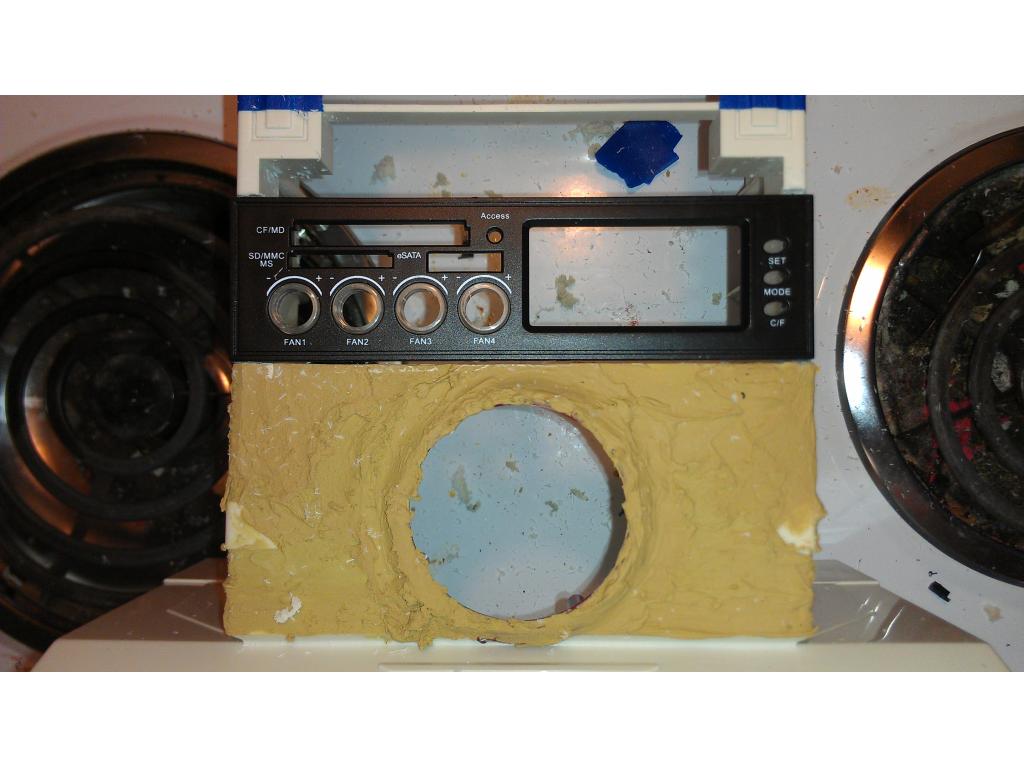
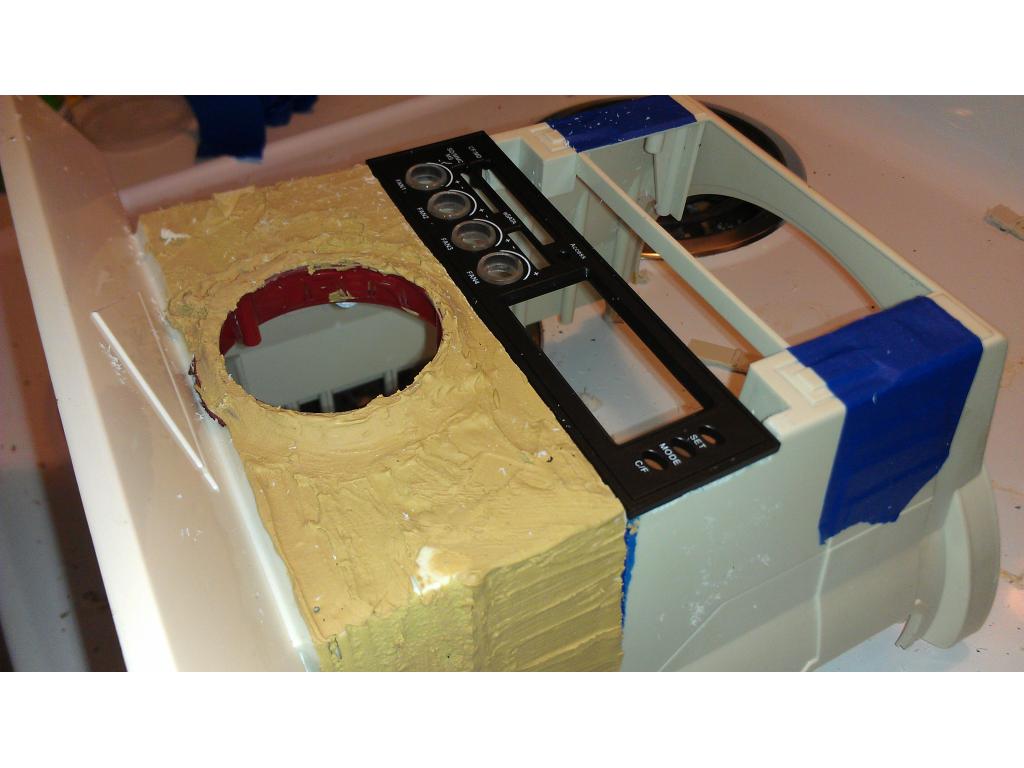
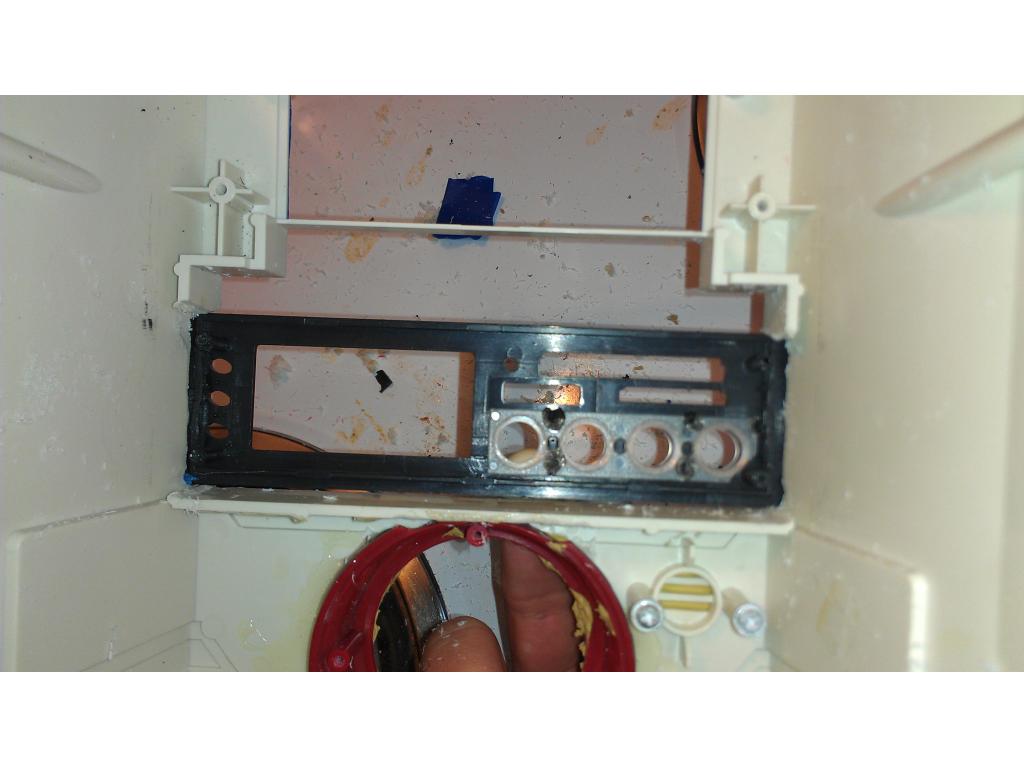
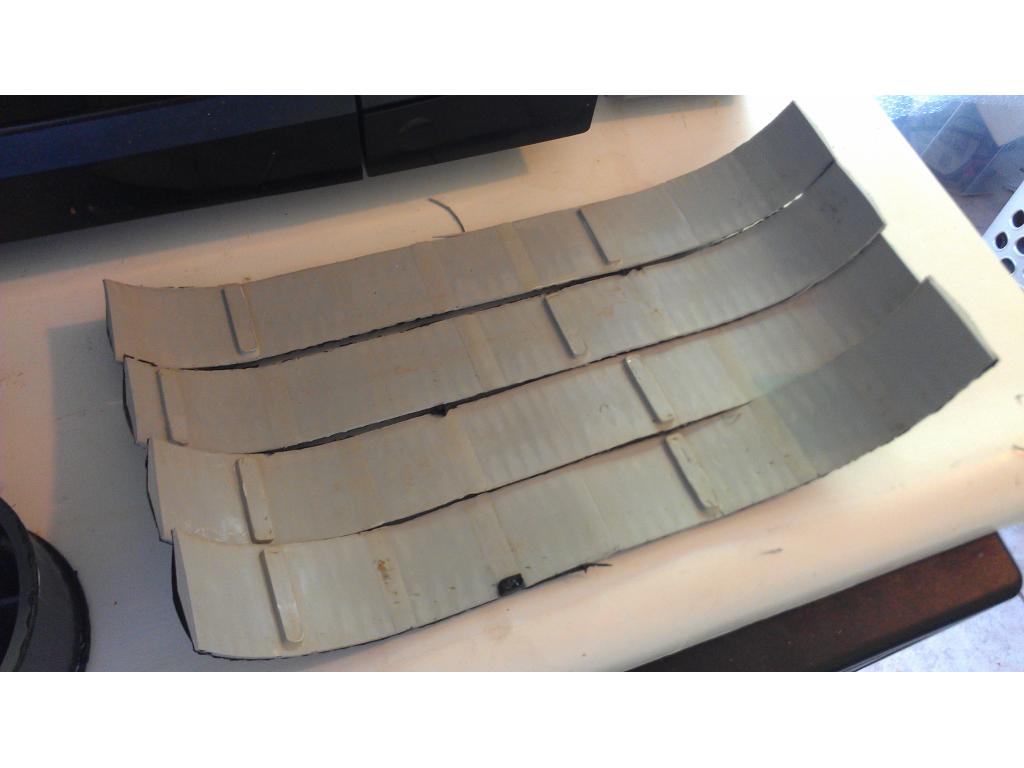
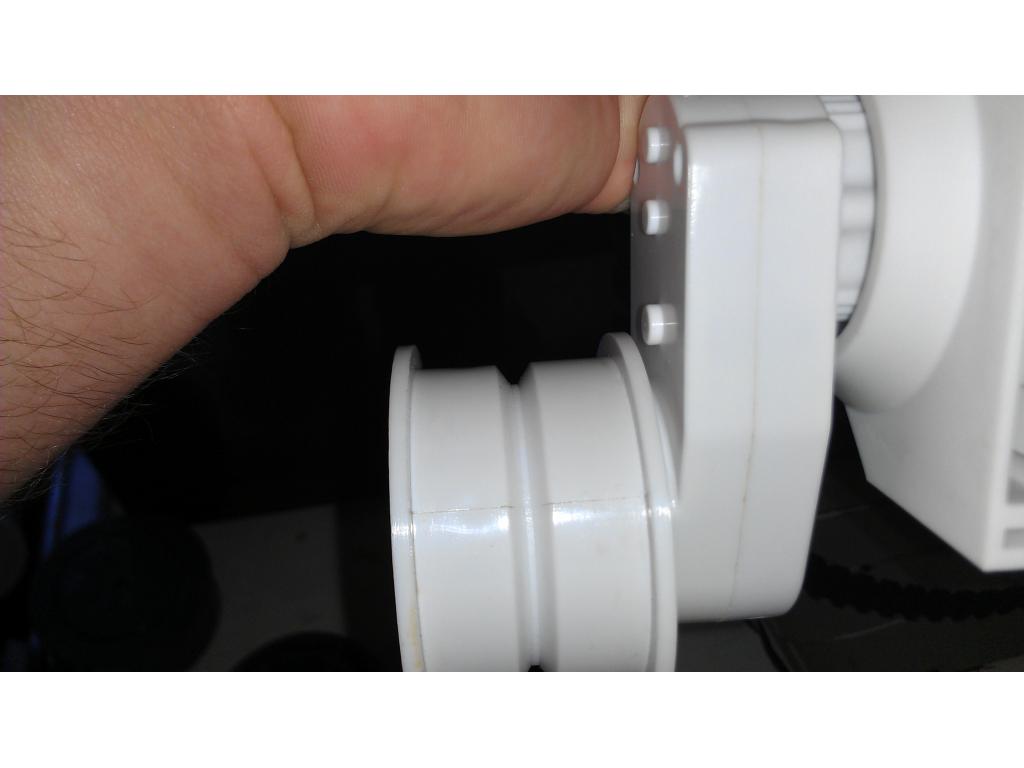
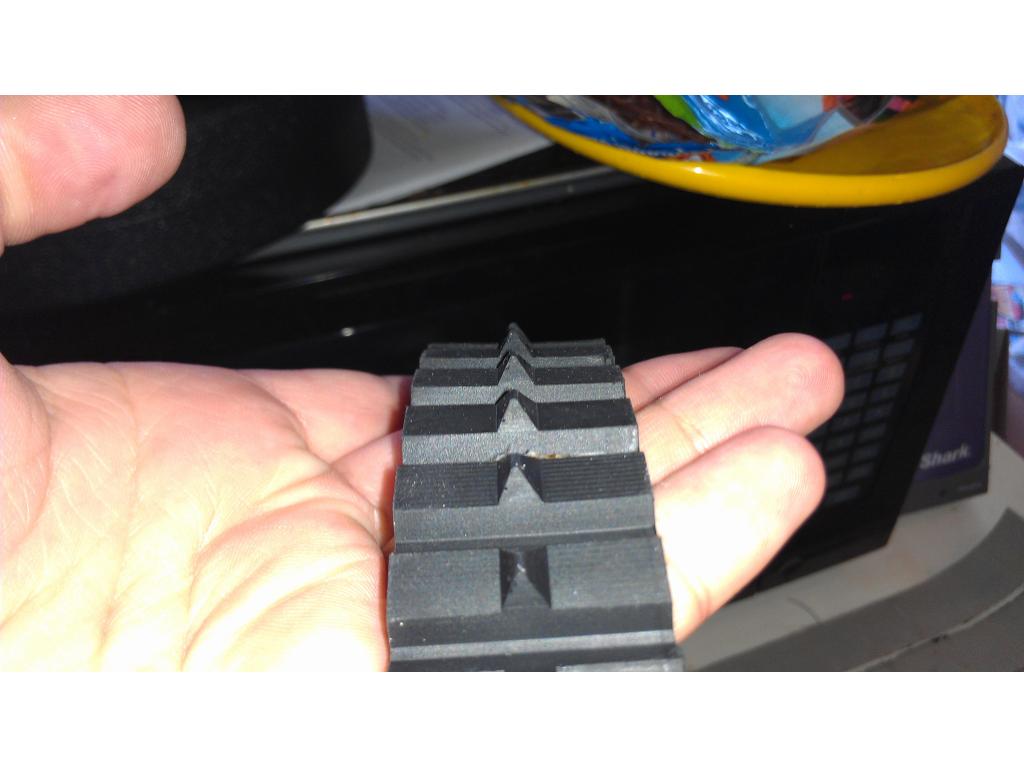
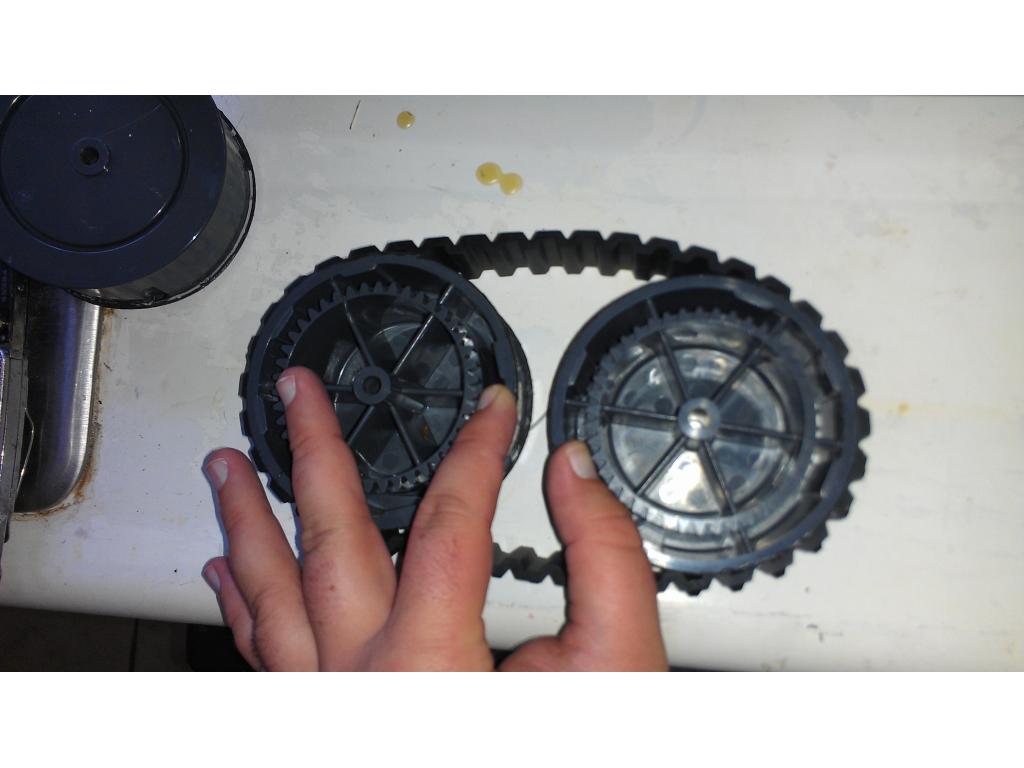
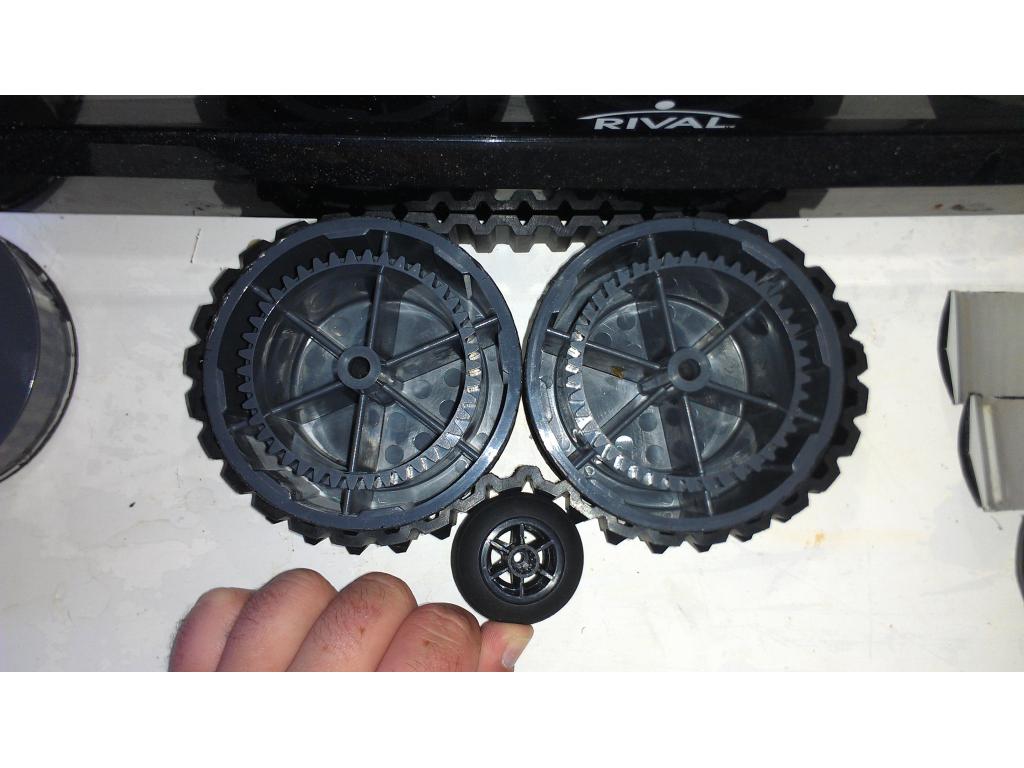
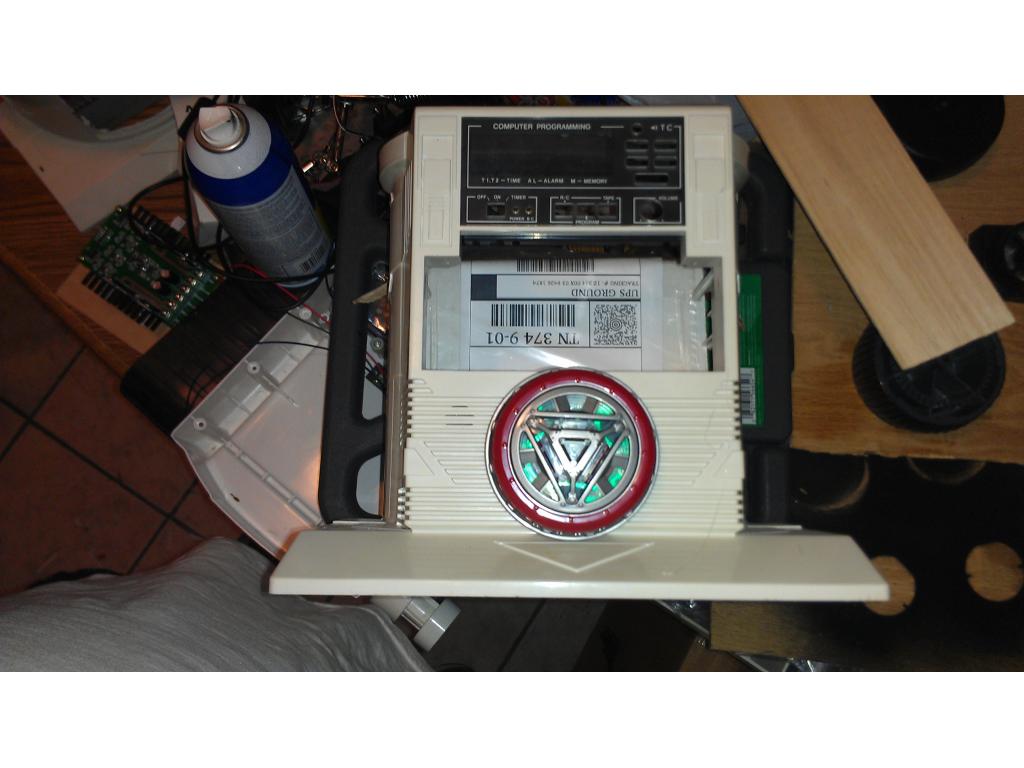
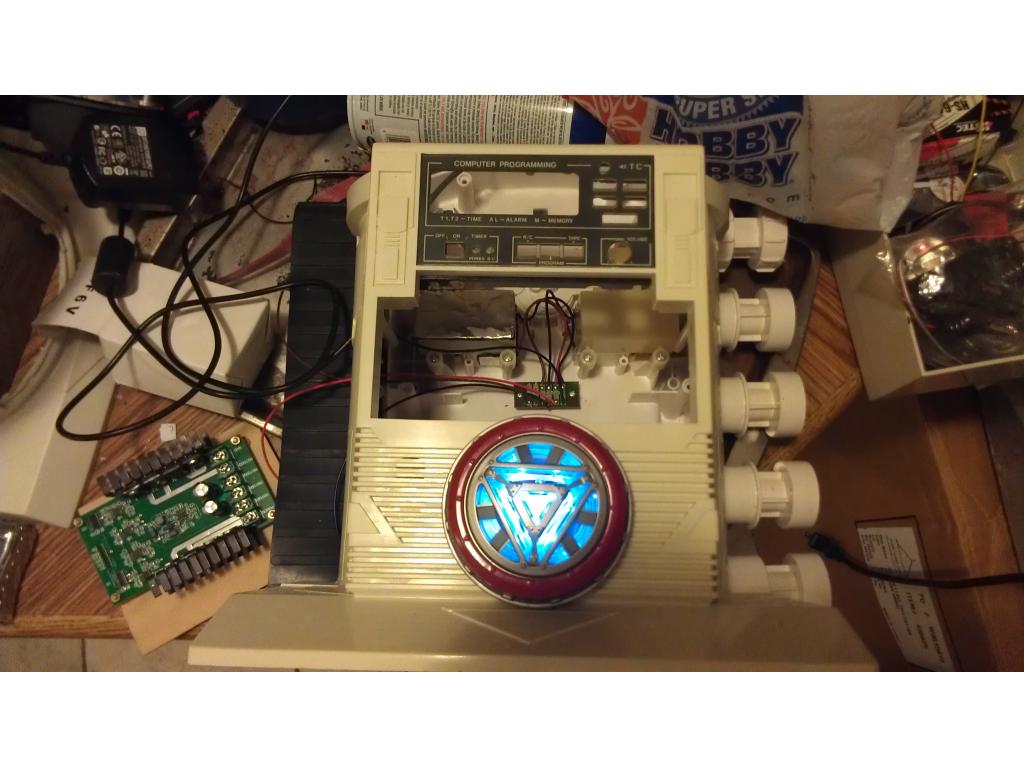
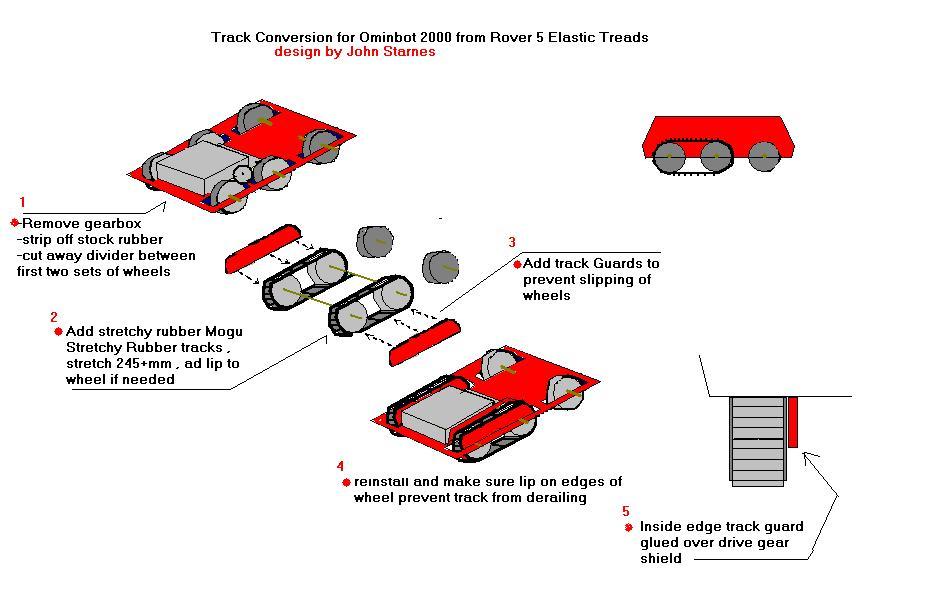
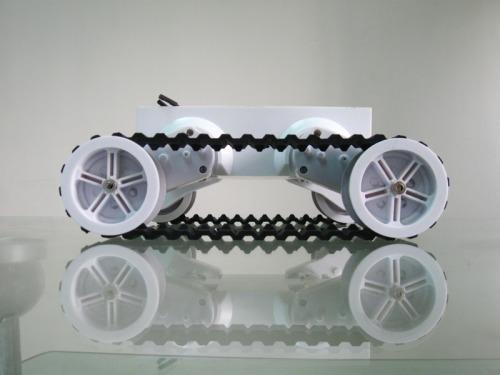
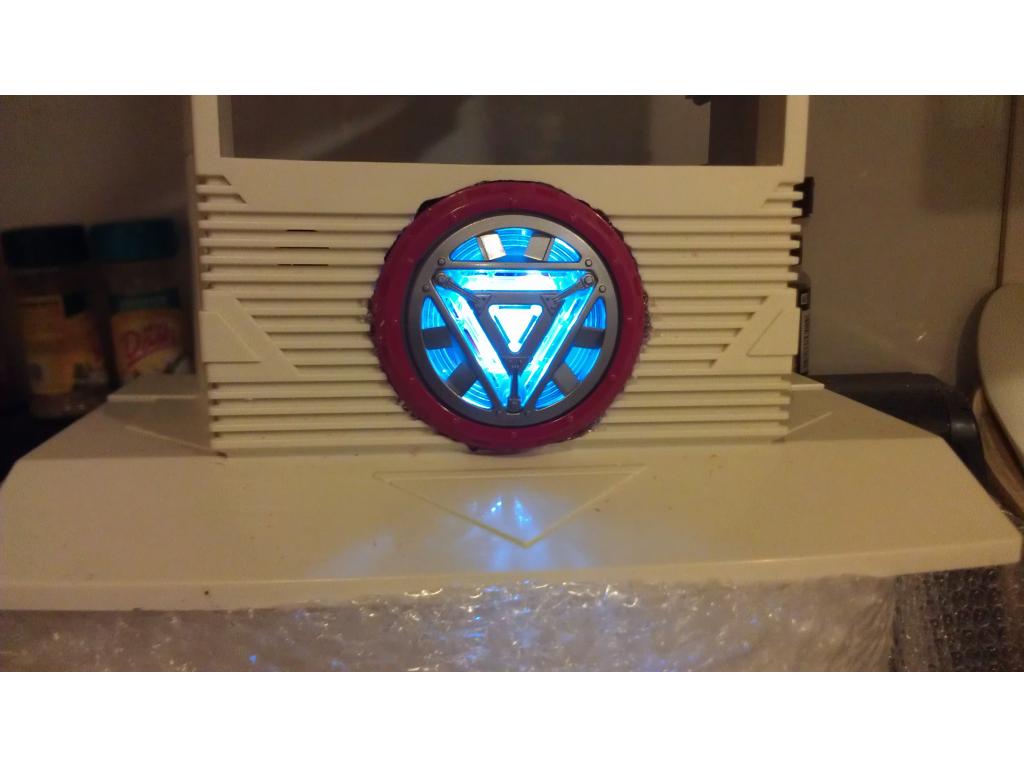
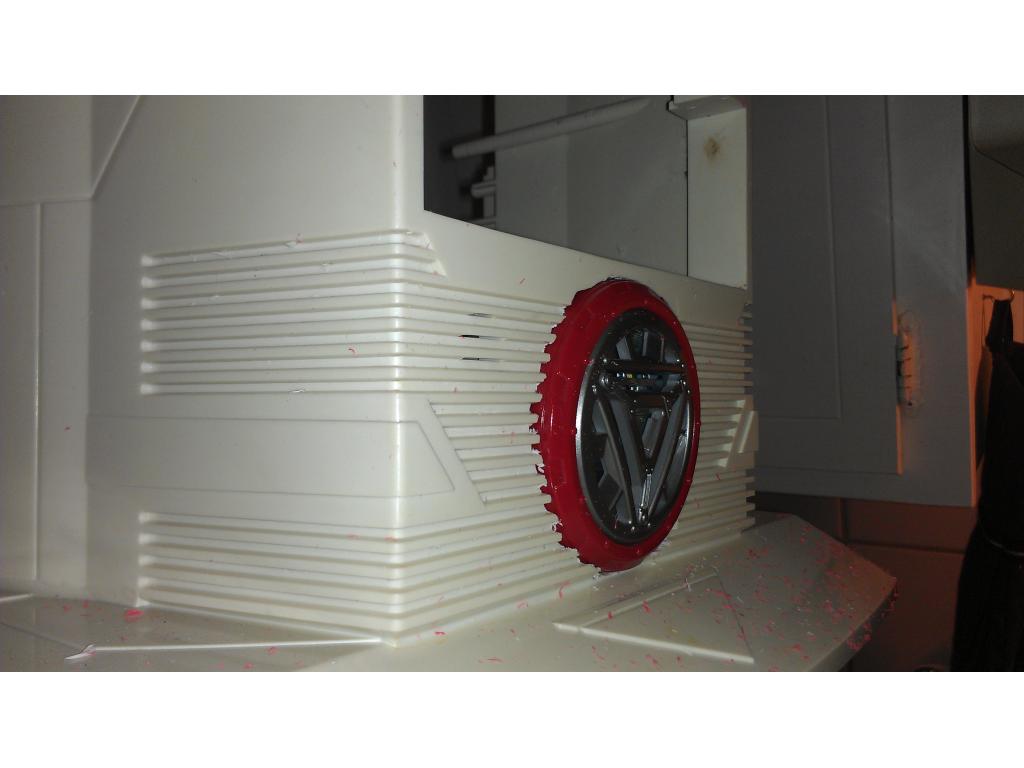
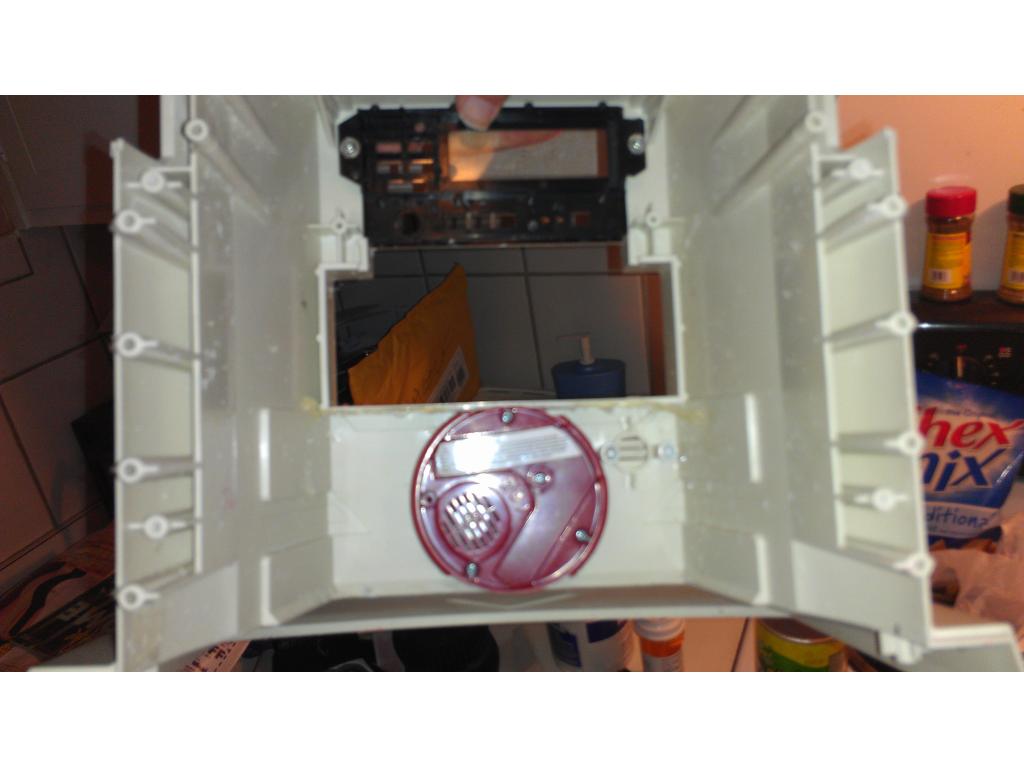
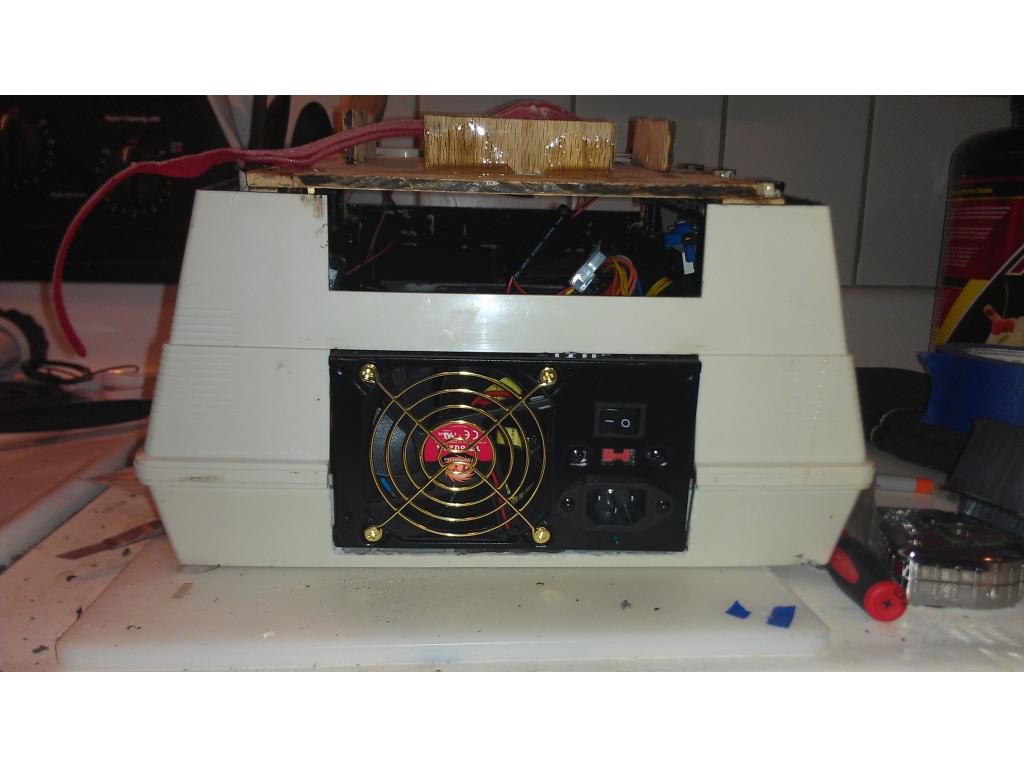
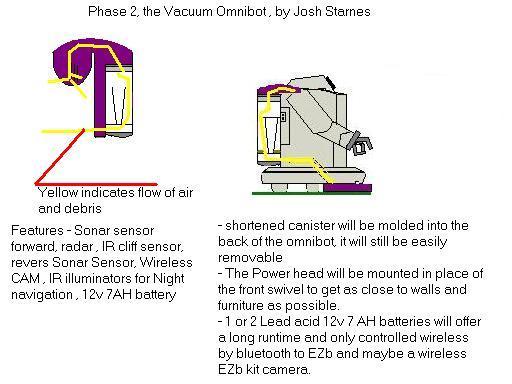
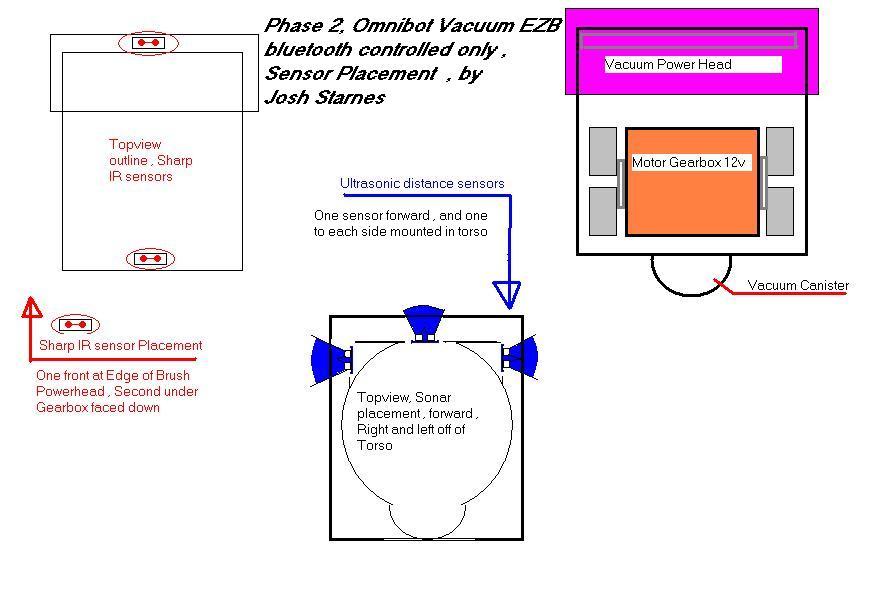
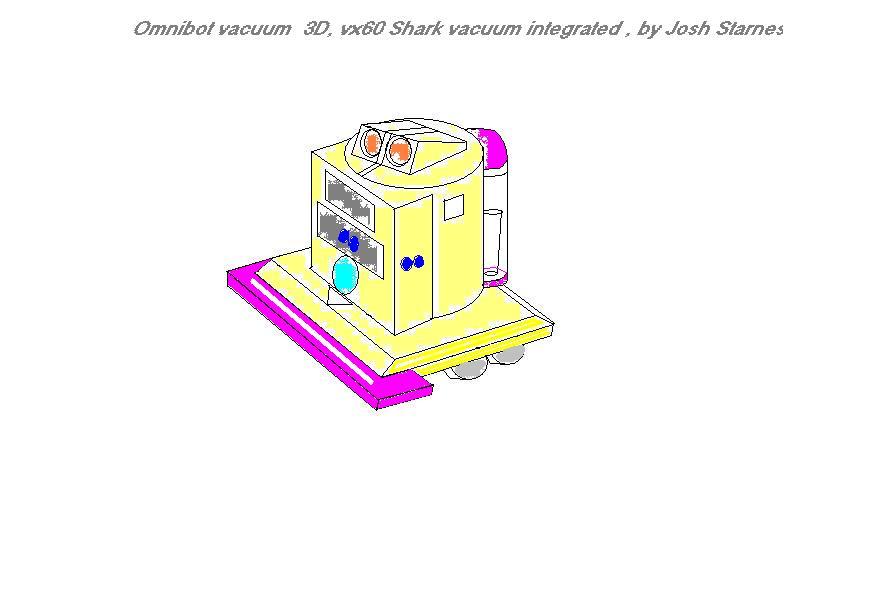
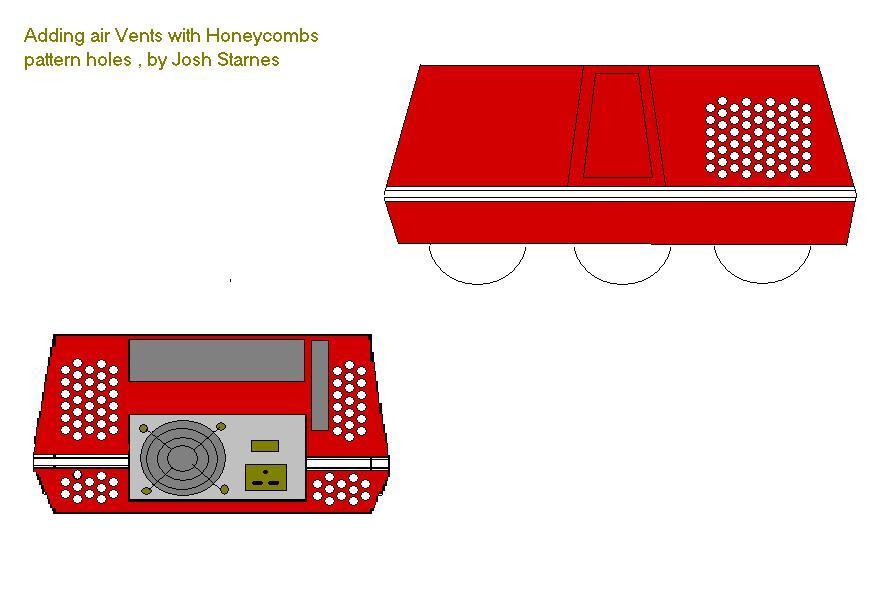
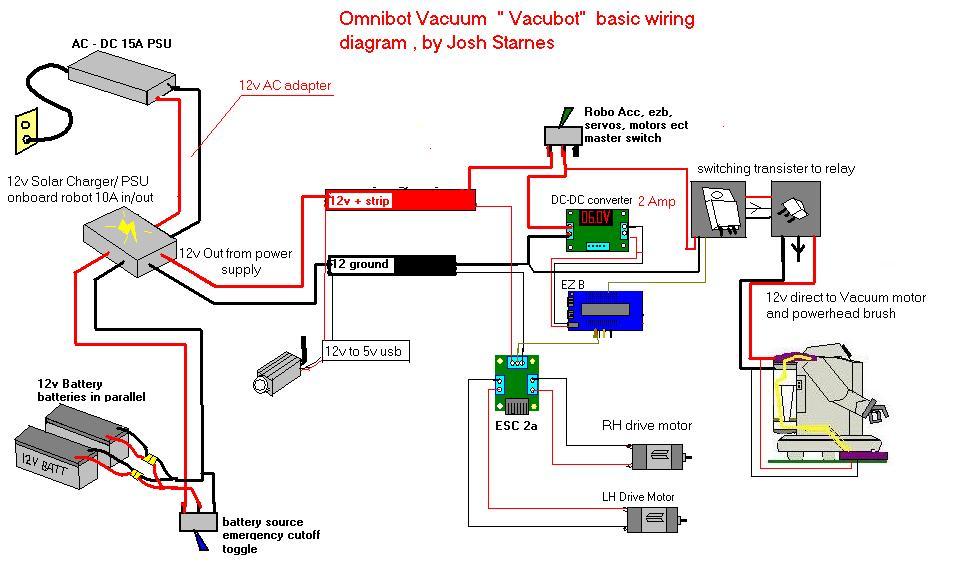
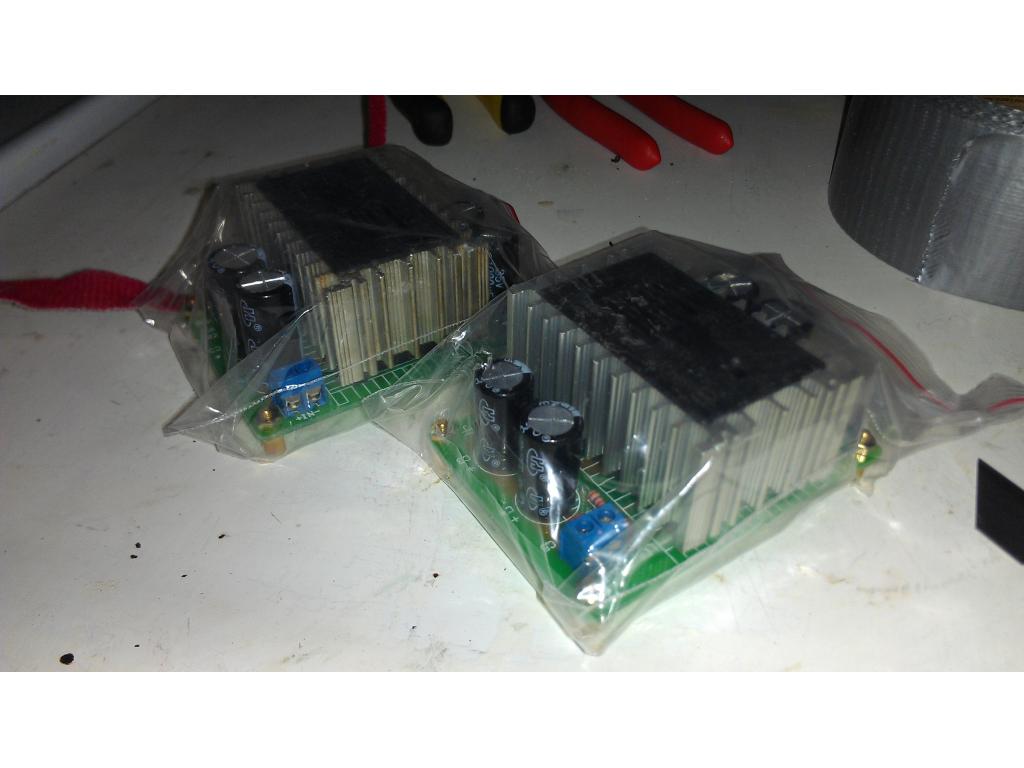
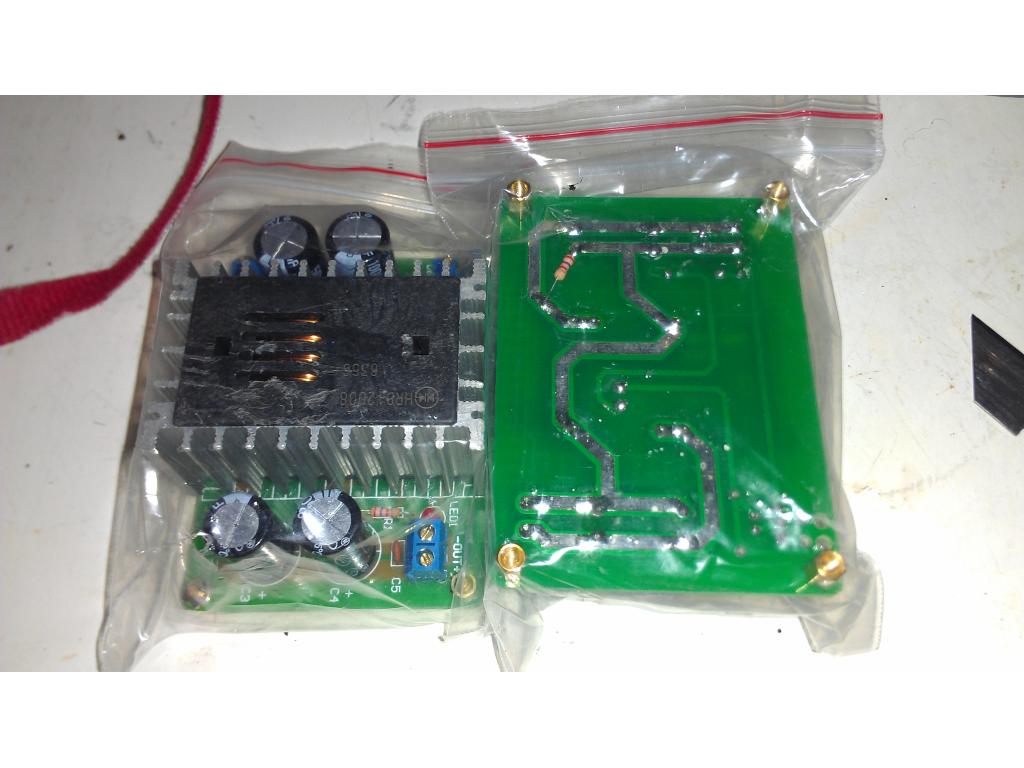
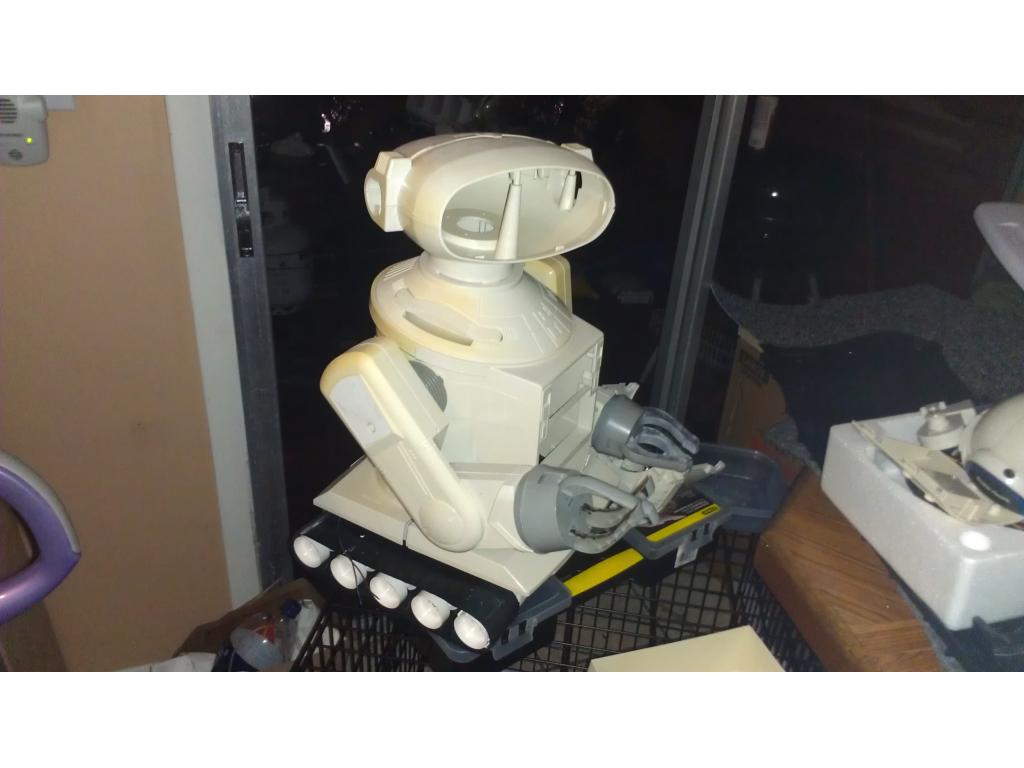
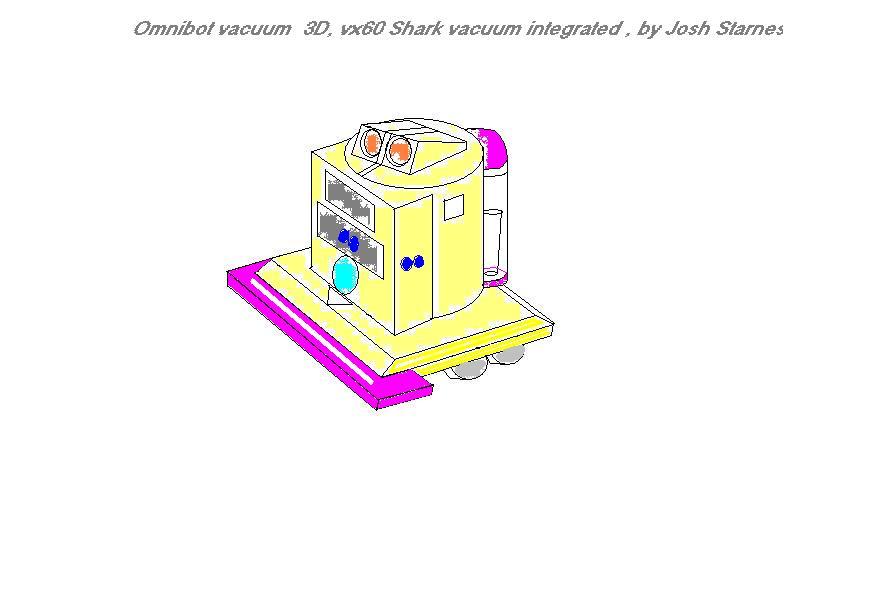
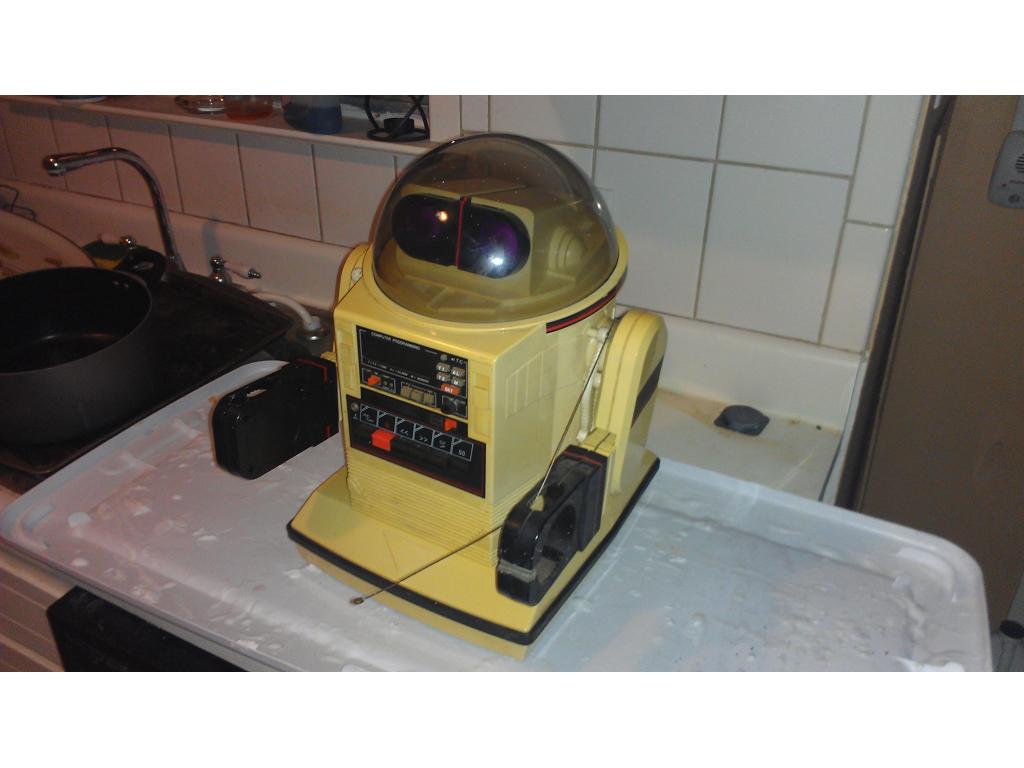
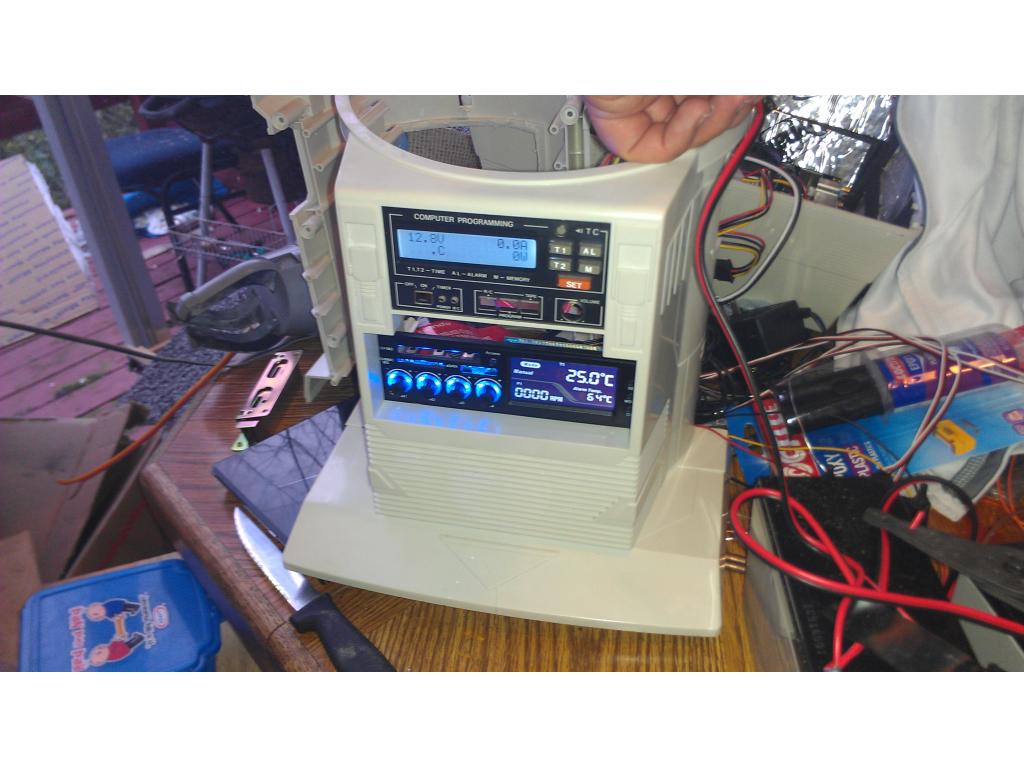
This project has evolved some , the basic rundown is I'm modding two Omnibots , one a regular the other a larger 2000 model. I will have two ezb kits , rad base idea was thrown out because of so much noise but could go back on the table if the omnibot drivetrain is too weak to pull it.
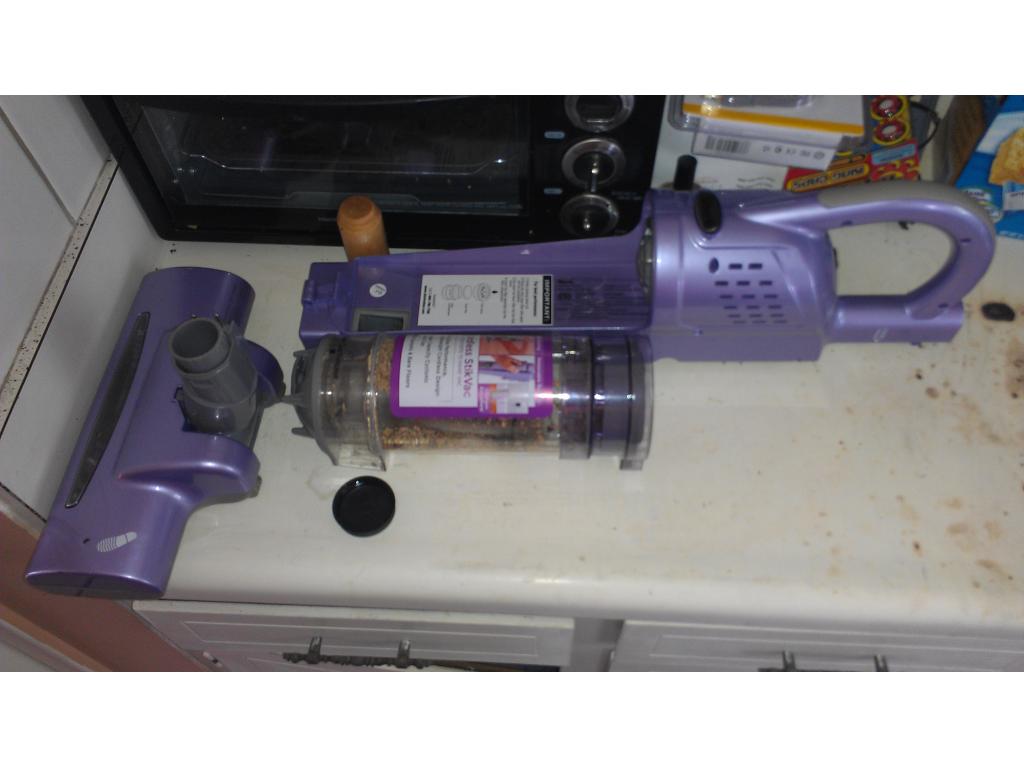
By jstarne1
— Last update
Discover more robots
DJ's Roli Rover Robot Chasing Red Ball
Control EZ-Robot Roli Rover with Synthiam ARC to chase a red ball using vision tracking for quick, entertaining...
Jphillipsnj's Inmoov Project
InMoov life-size open-source 3D-print robot project using EZ-Robot and EZ Face, exploring Kinect support and VB.net...
Sakis33's Maria ,The Green Bot
Maria robot runs on LiPo or 10W solar power with a DC-DC 9V regulator, battery monitor and two hands for grasping,...


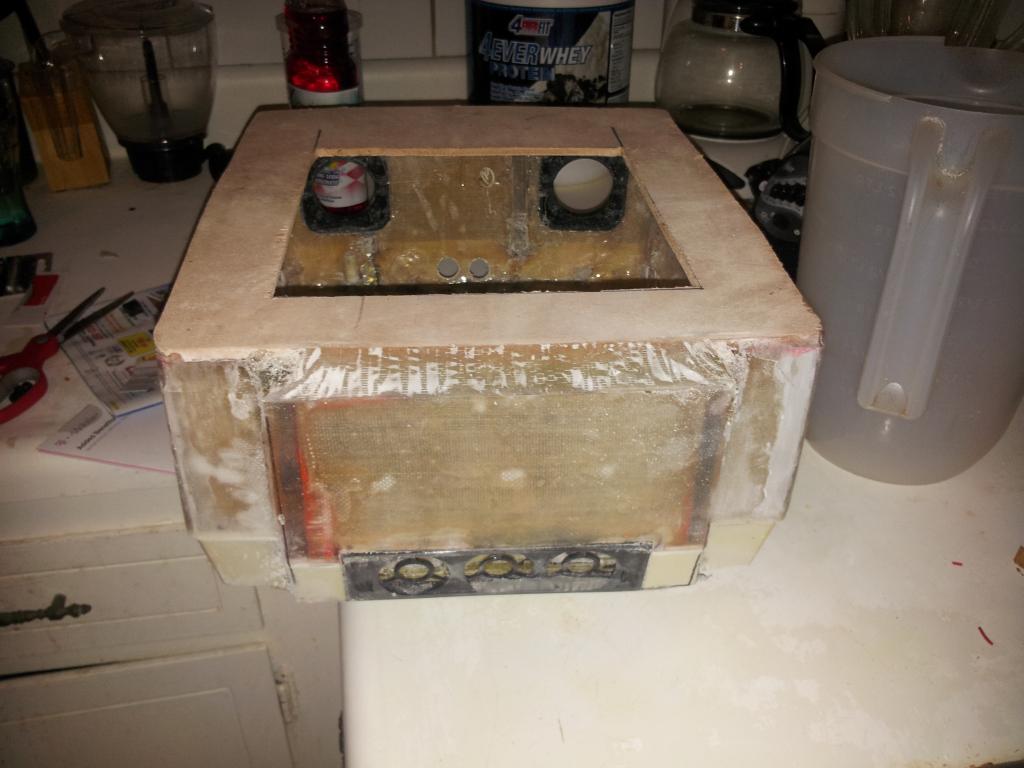
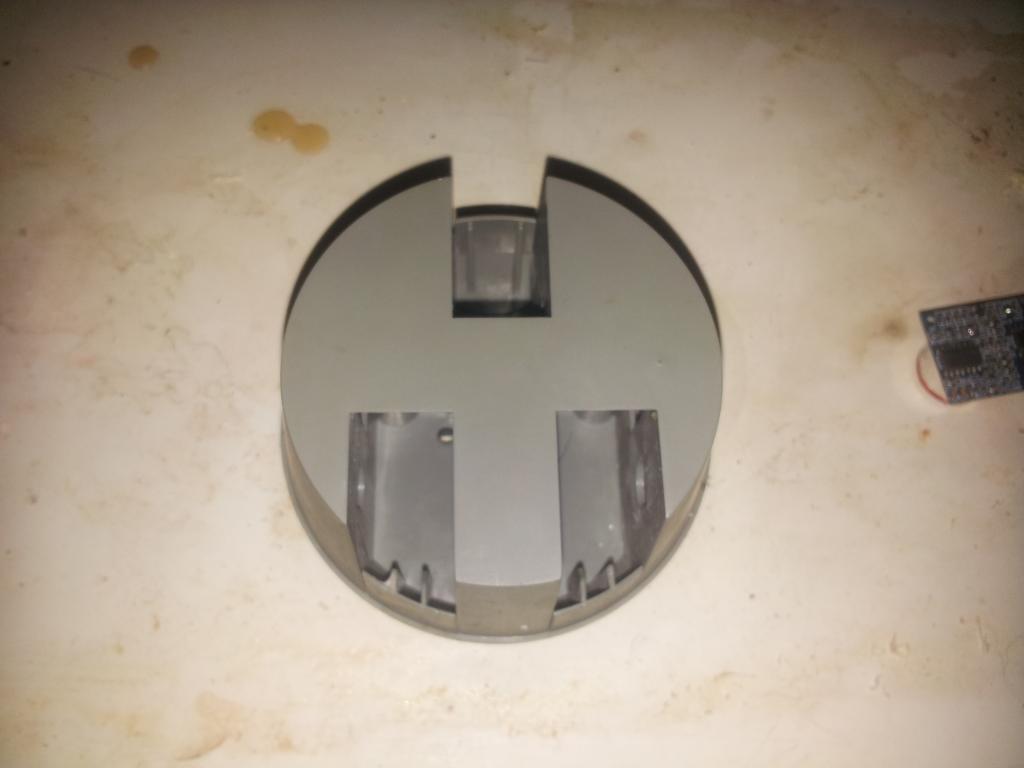
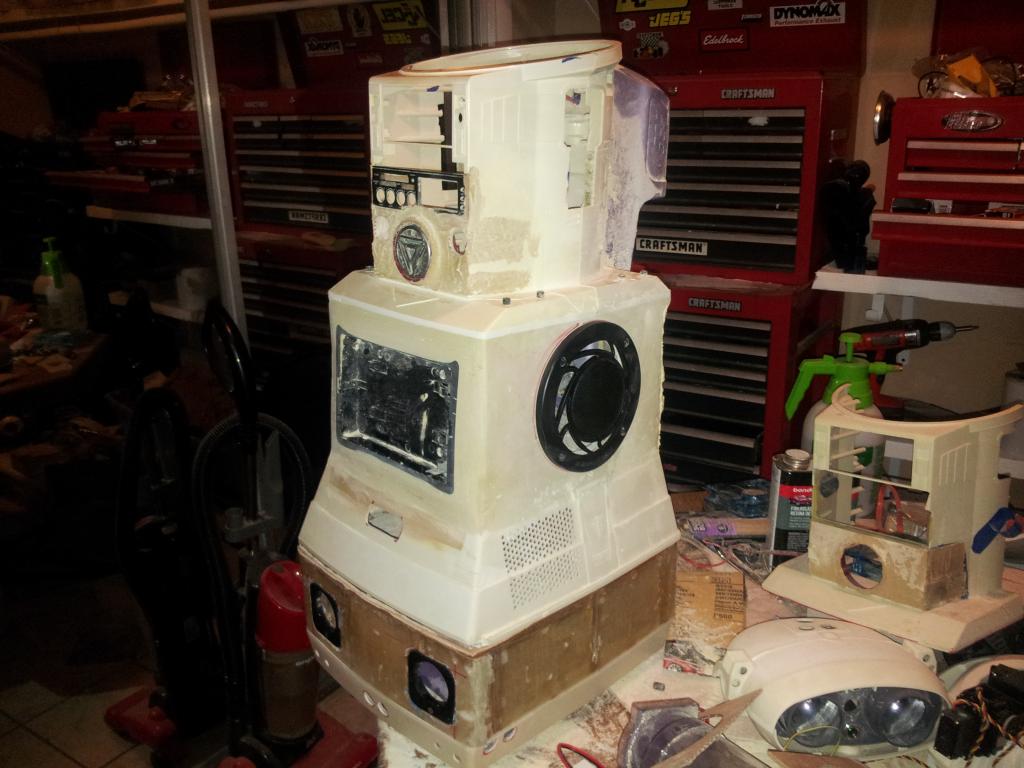
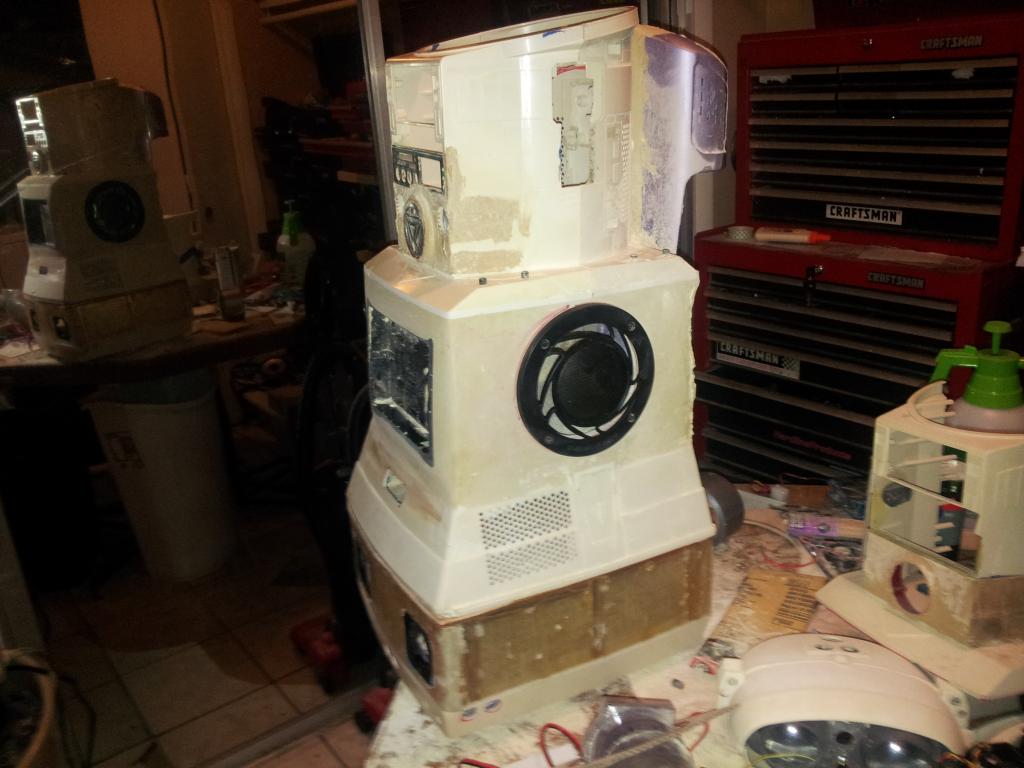
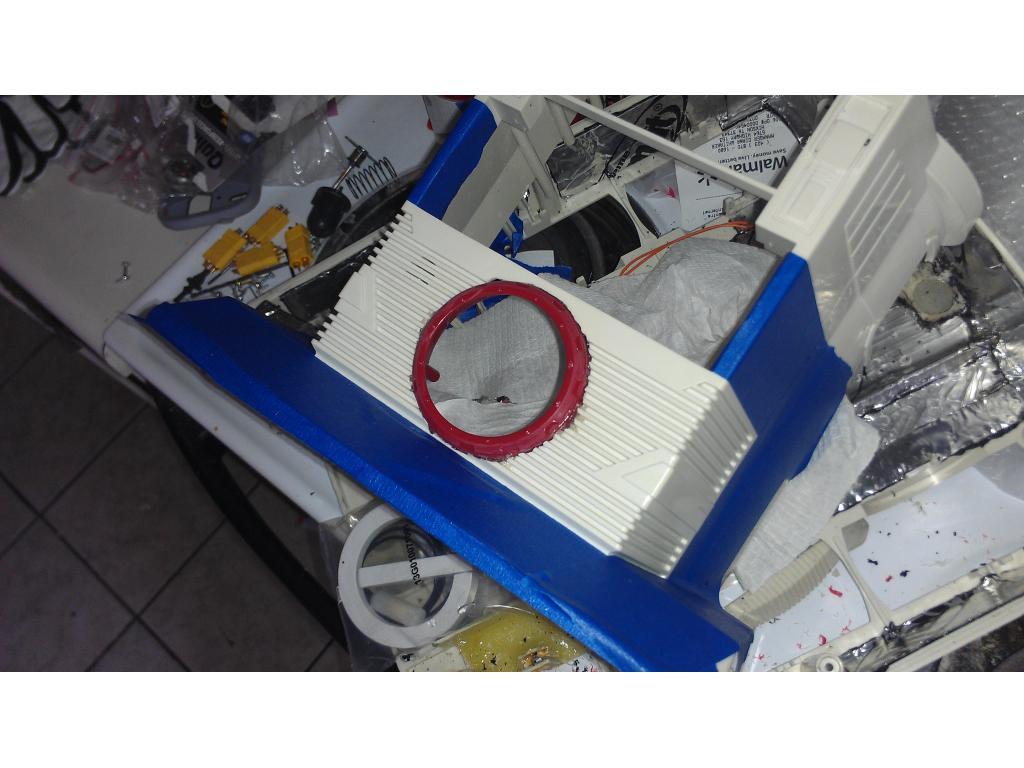
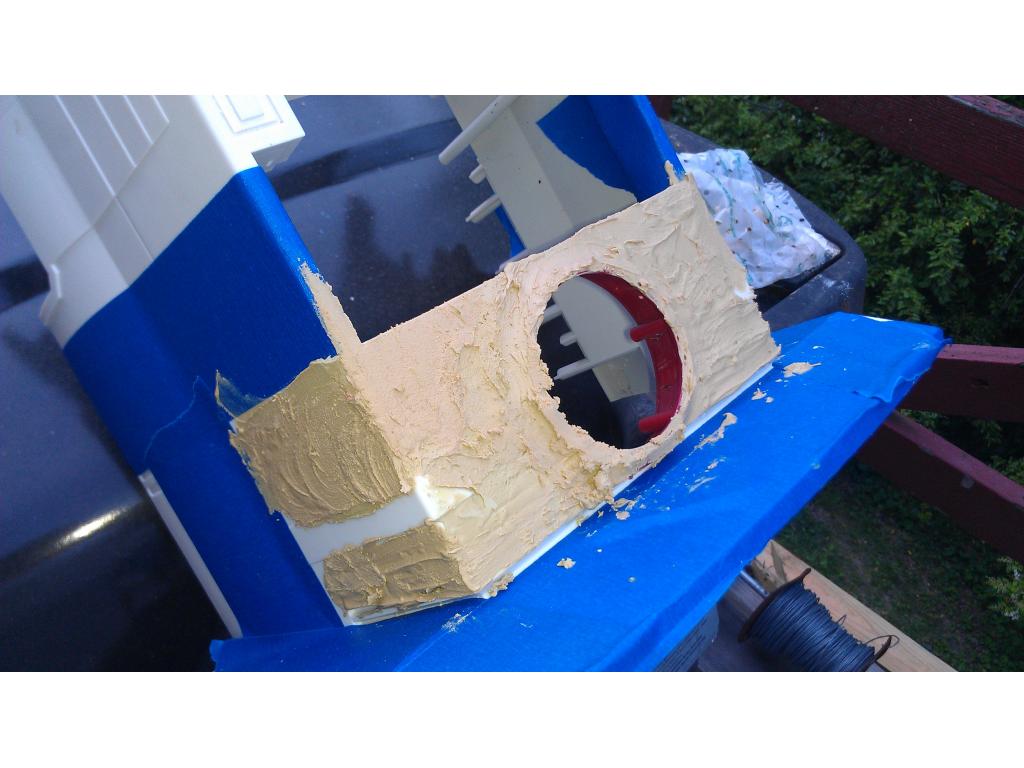
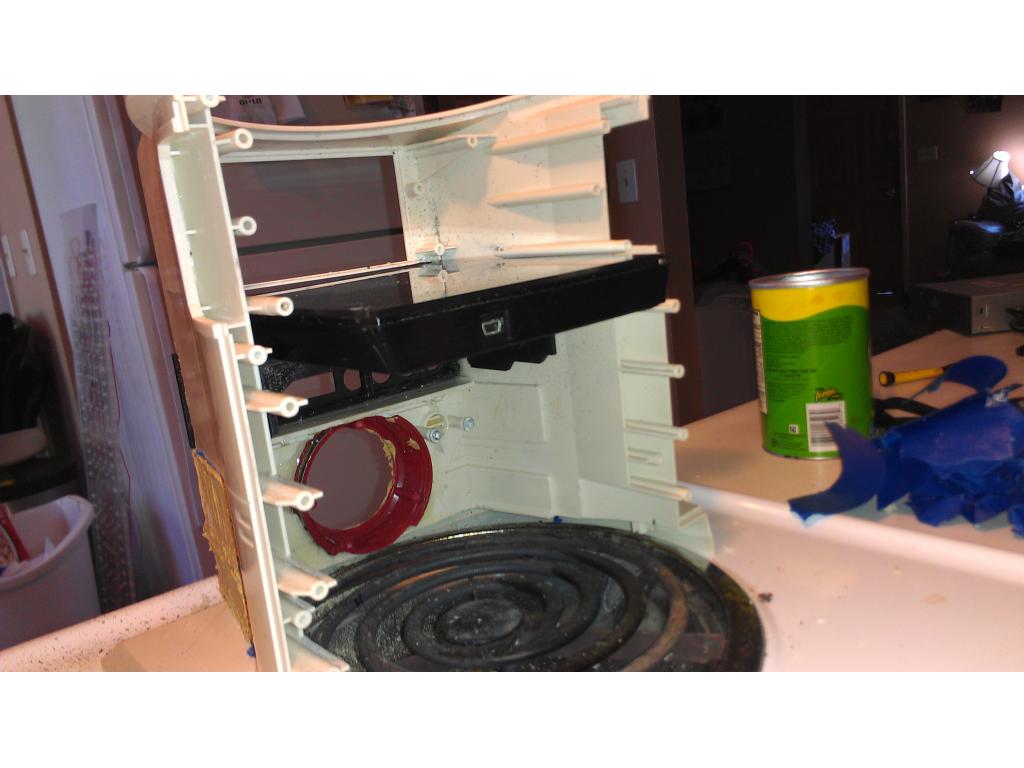
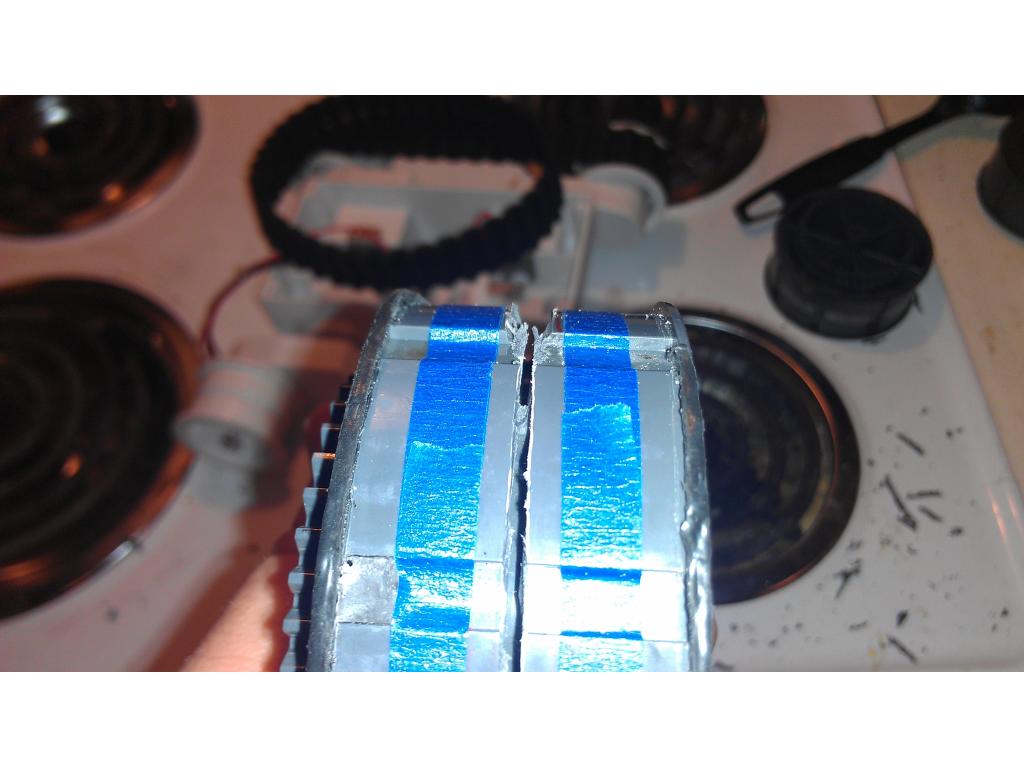
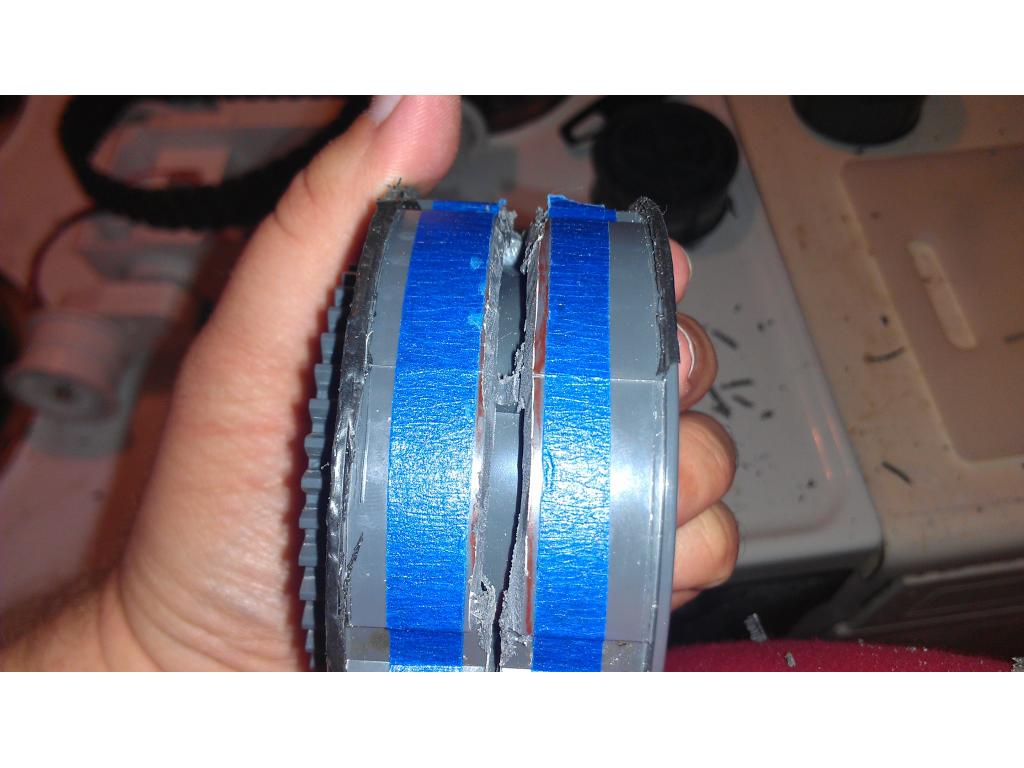
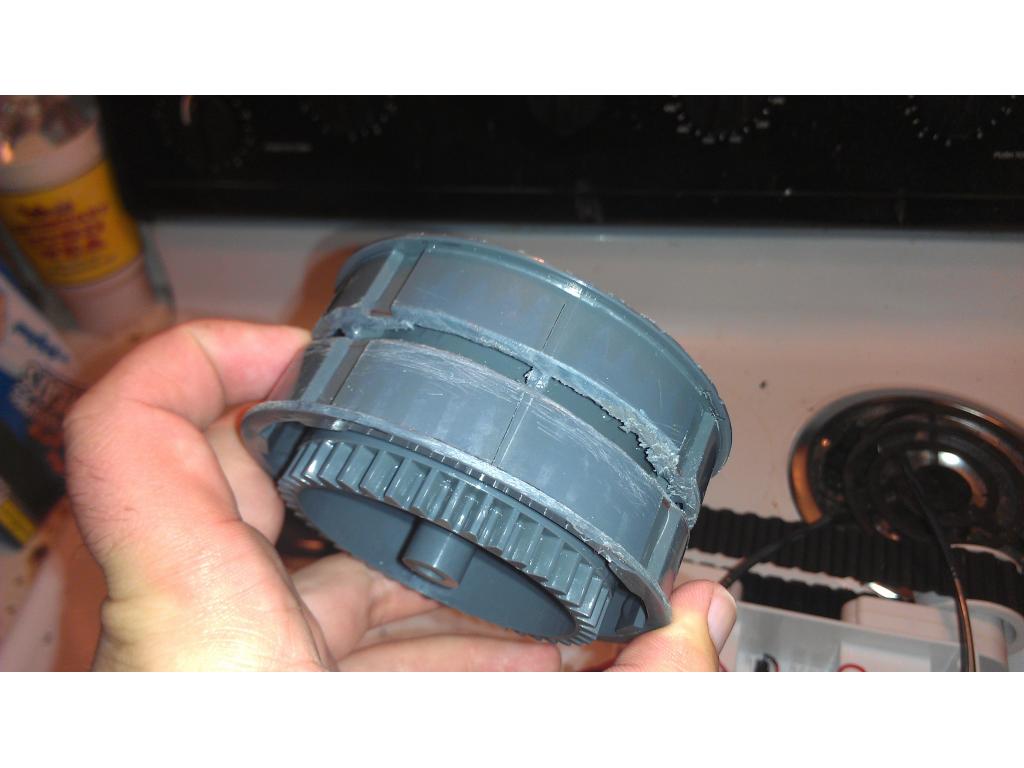
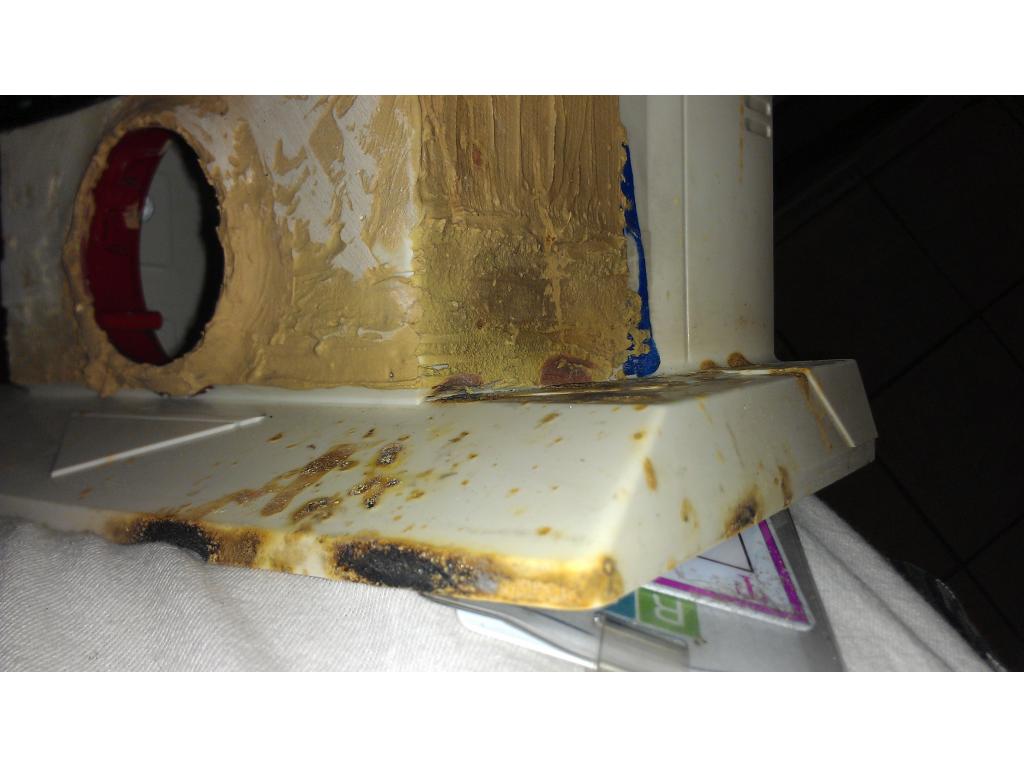
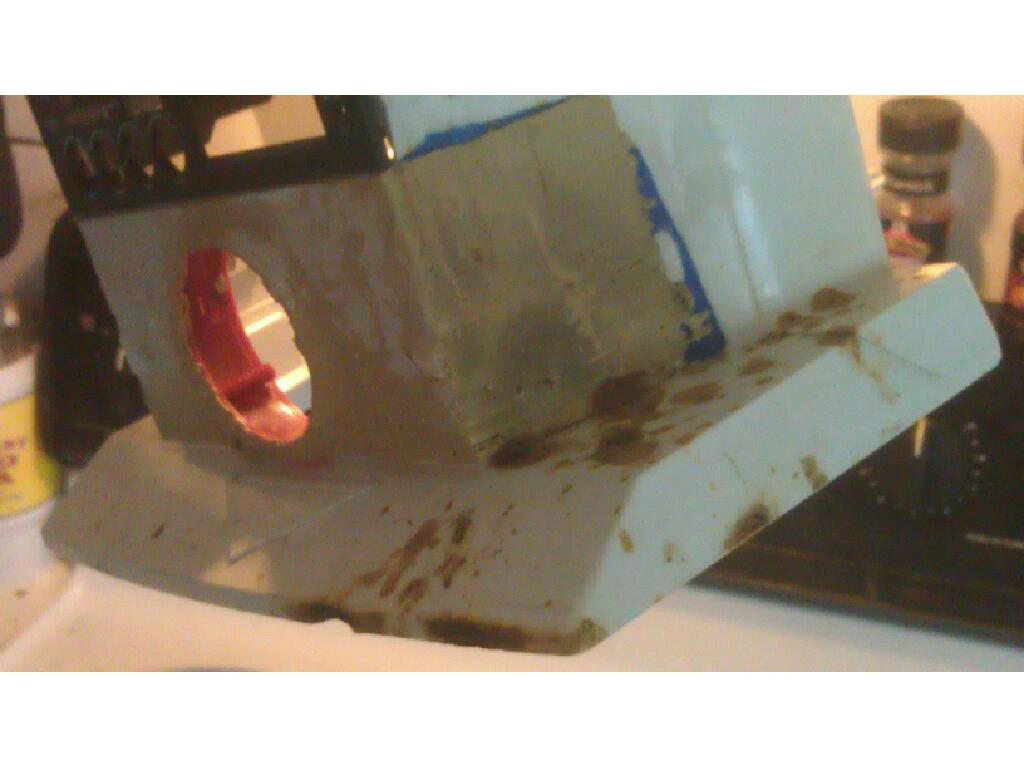
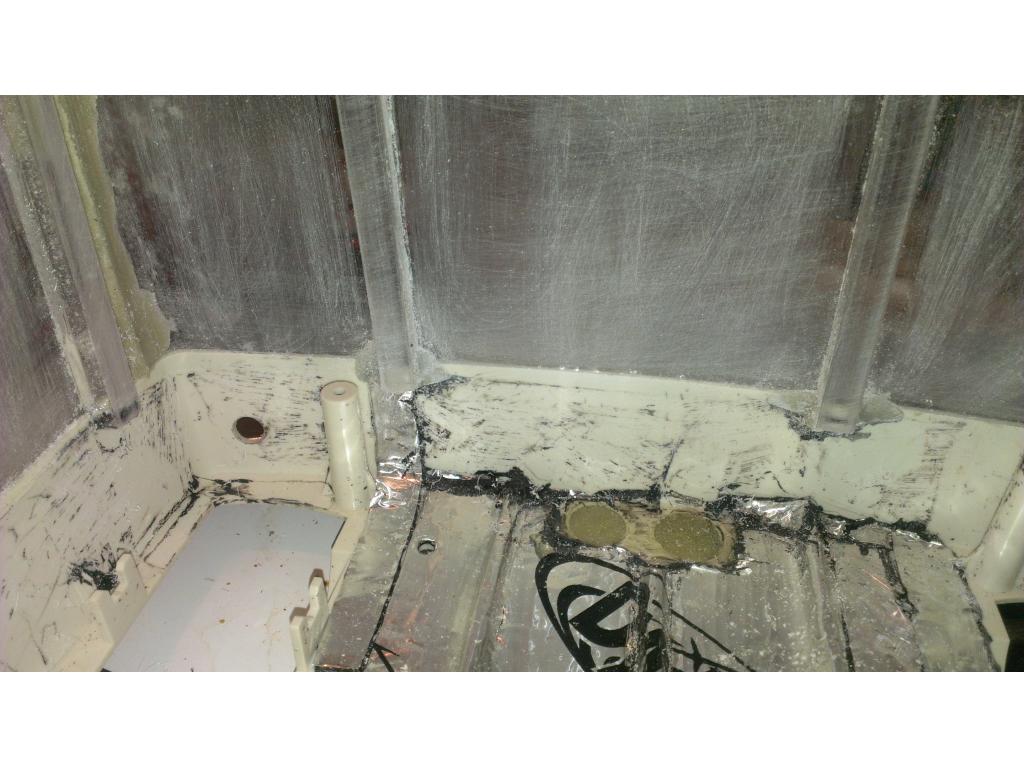
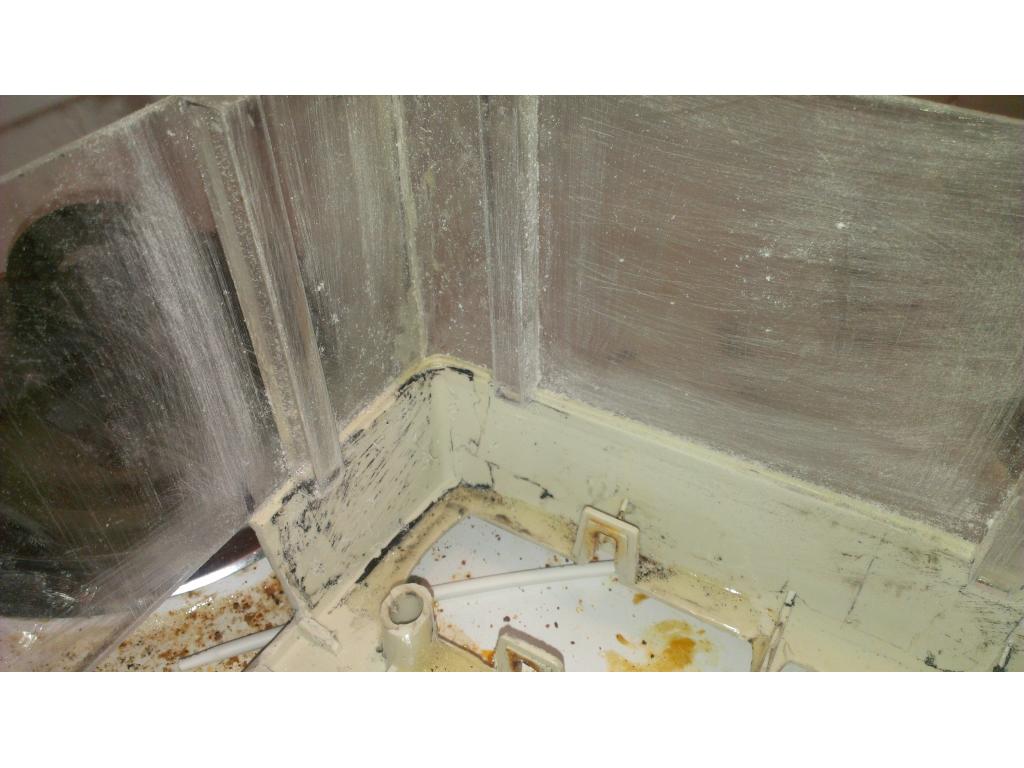
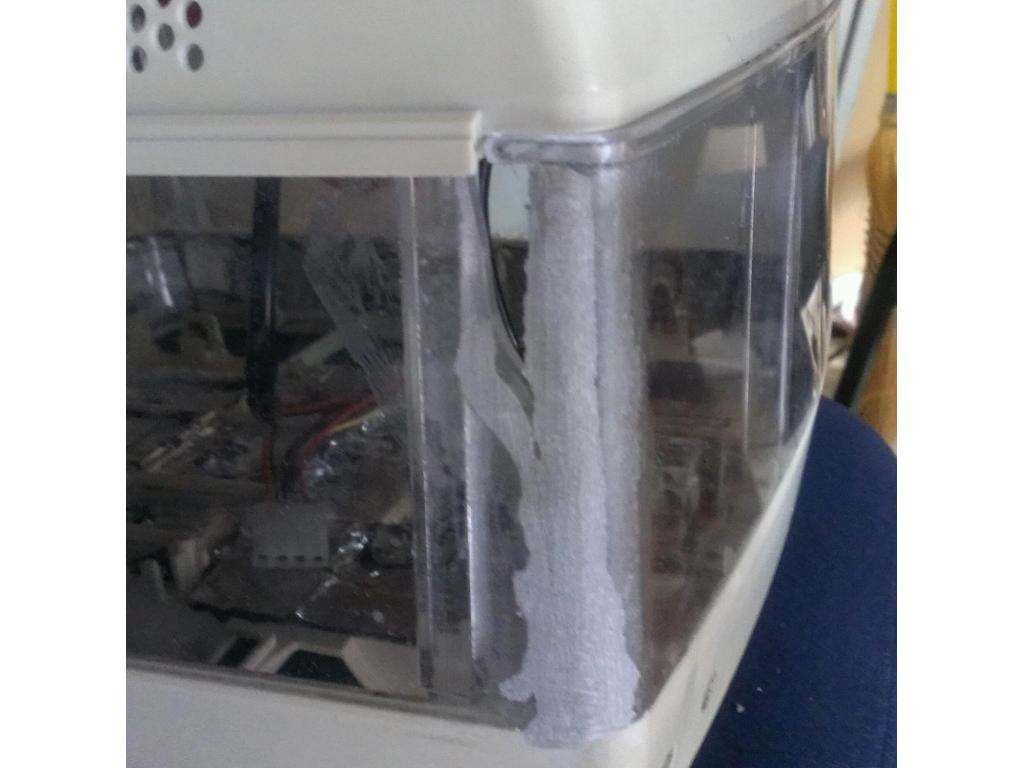
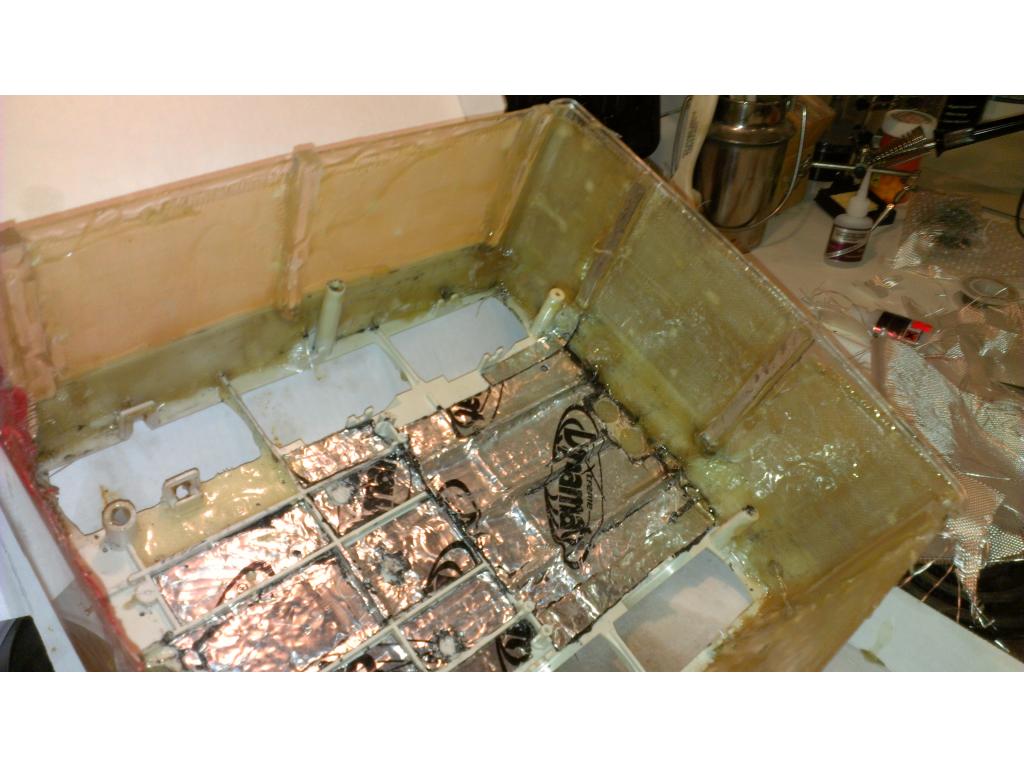
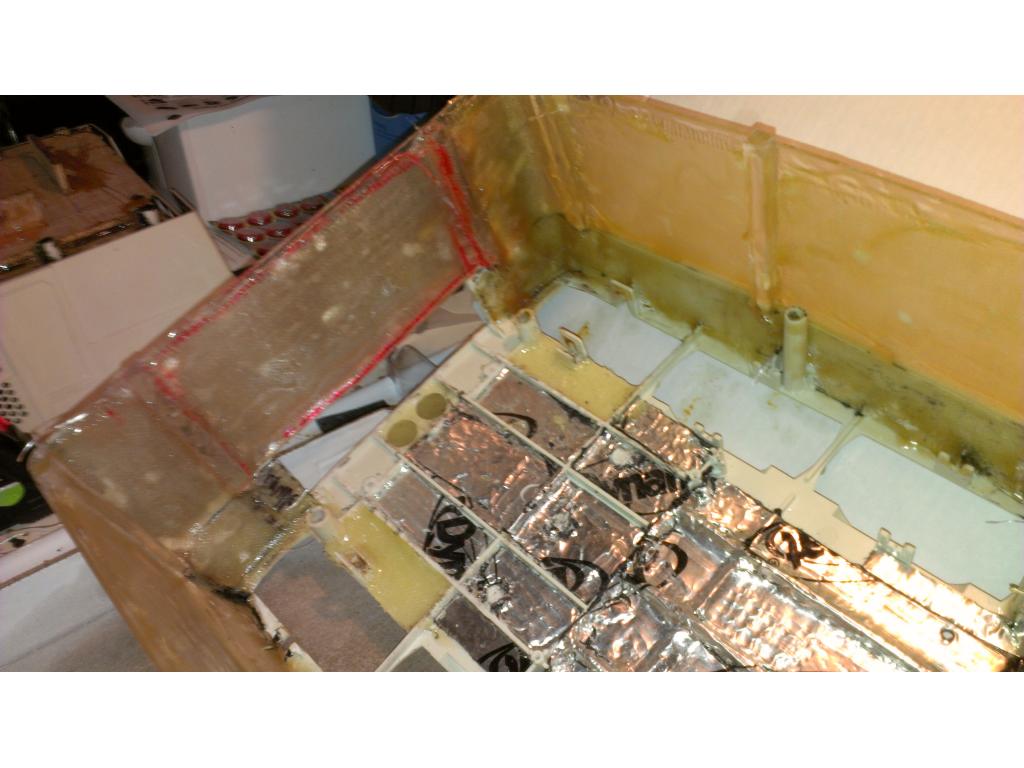
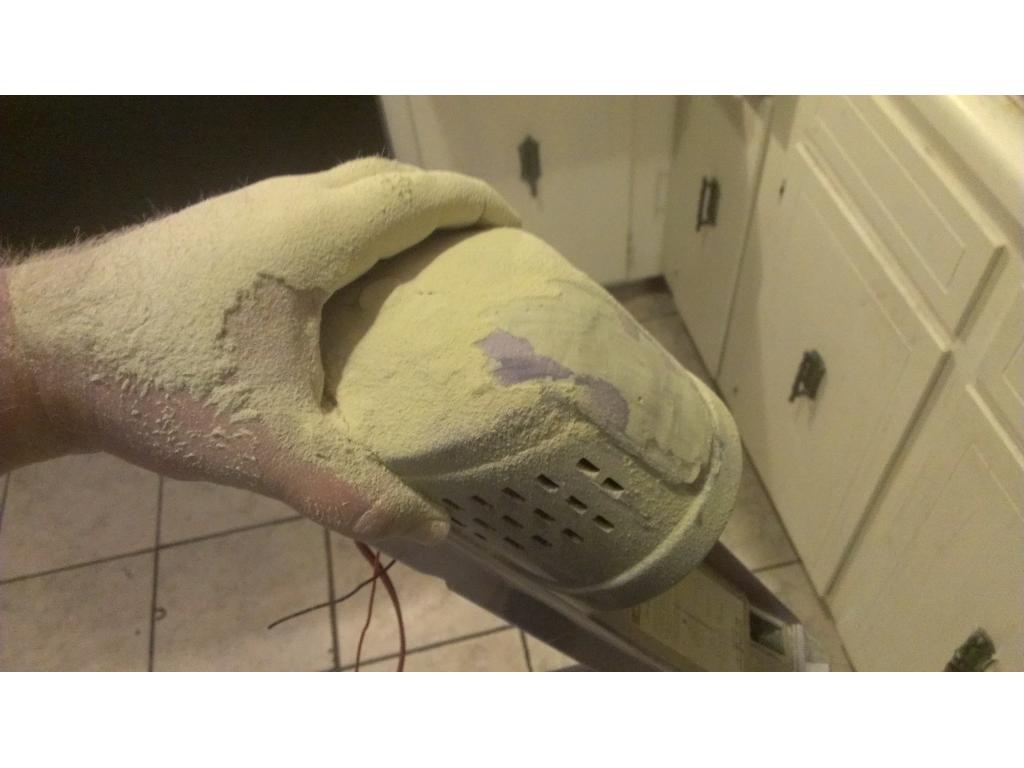
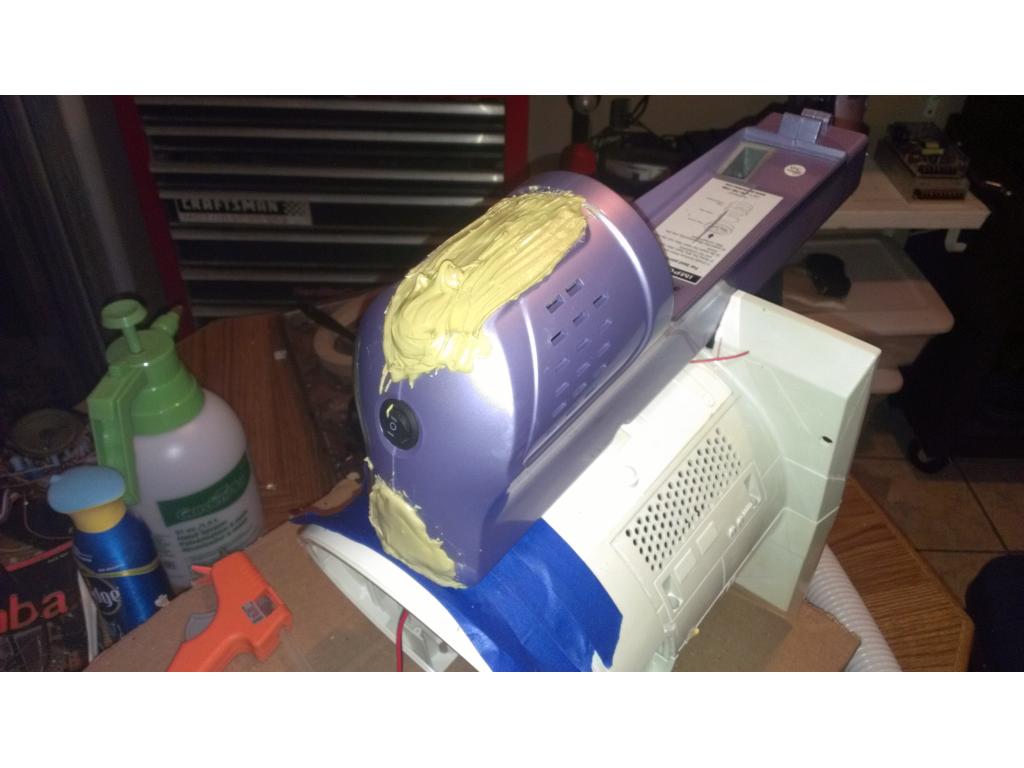
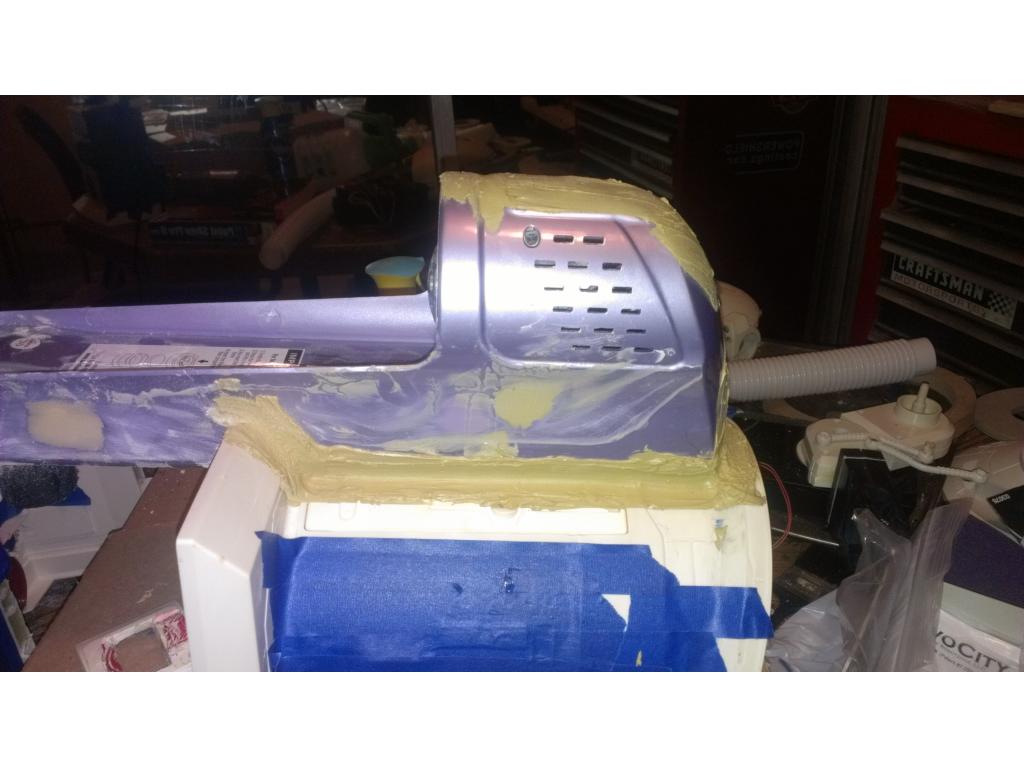
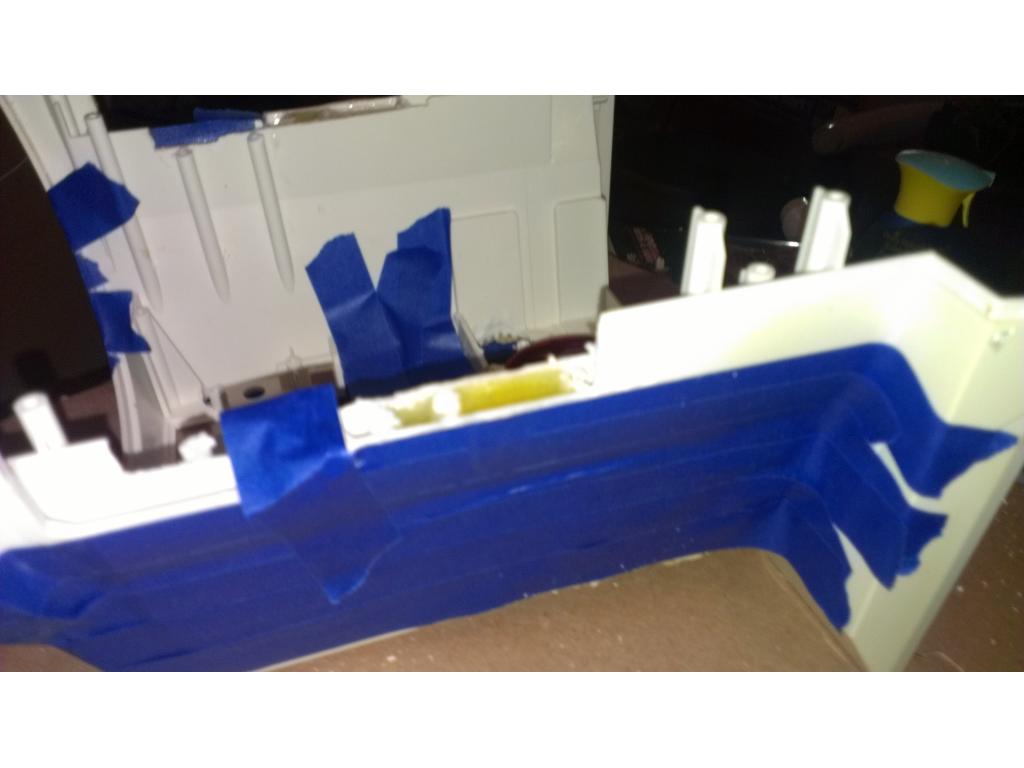
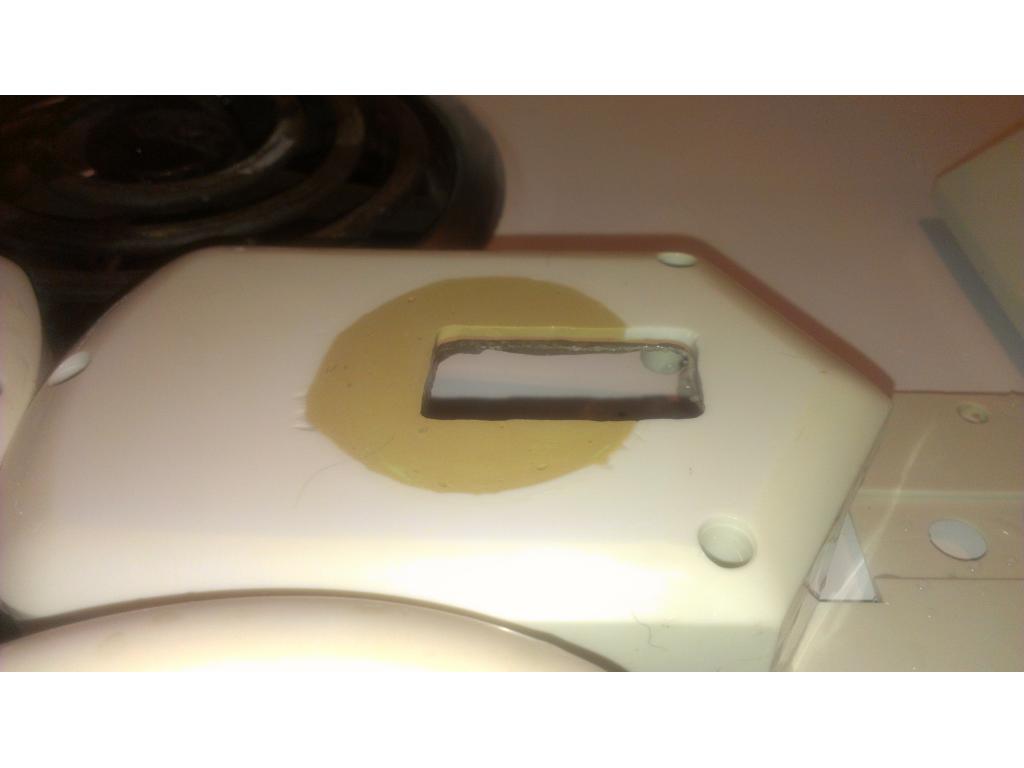
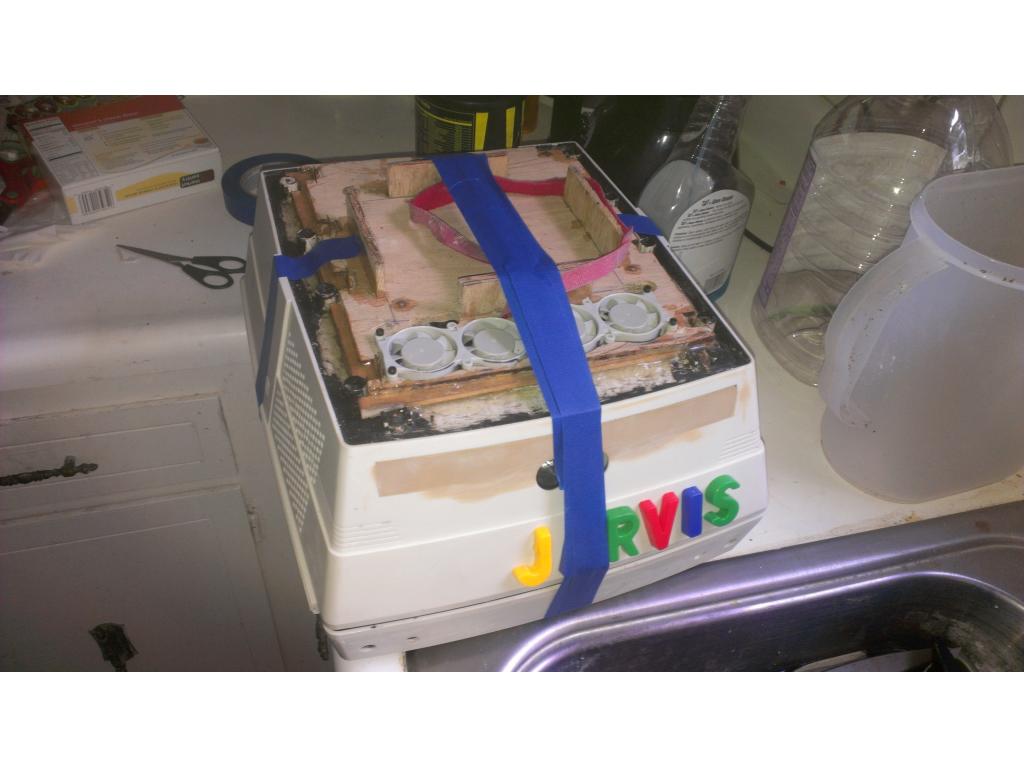
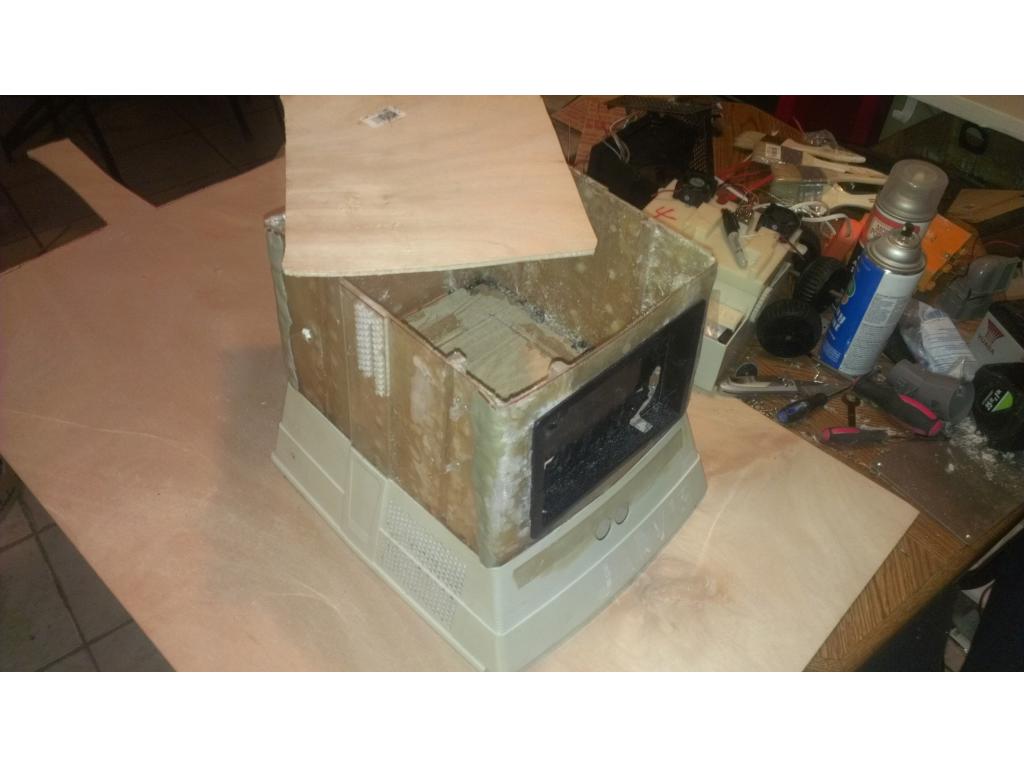
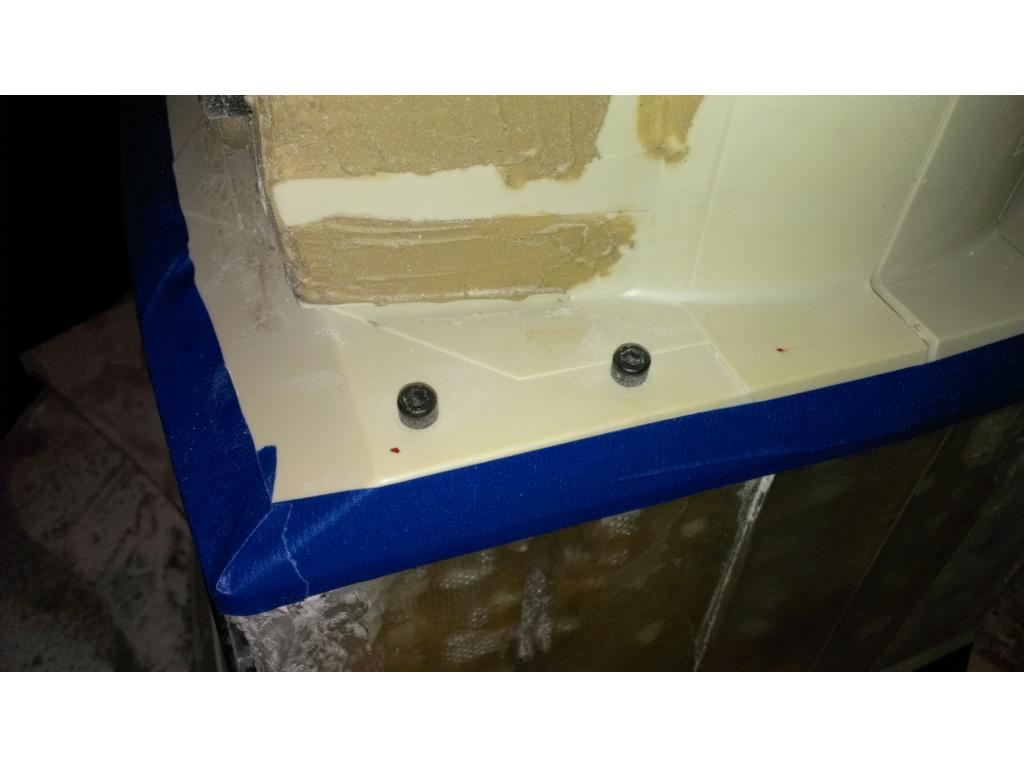
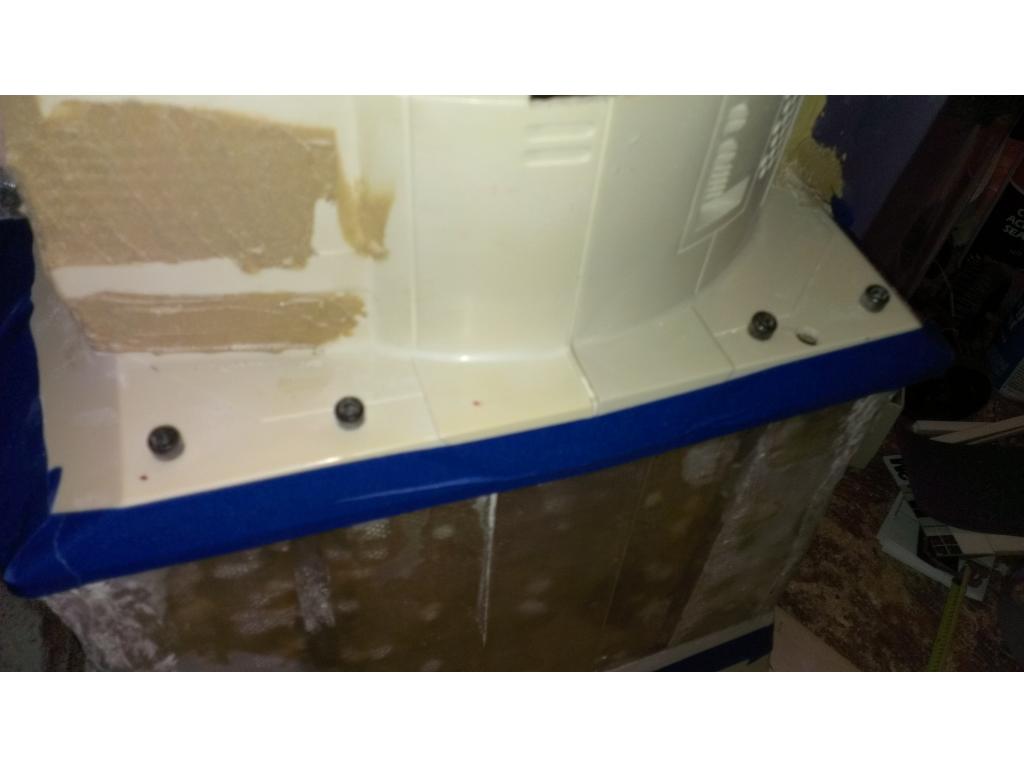
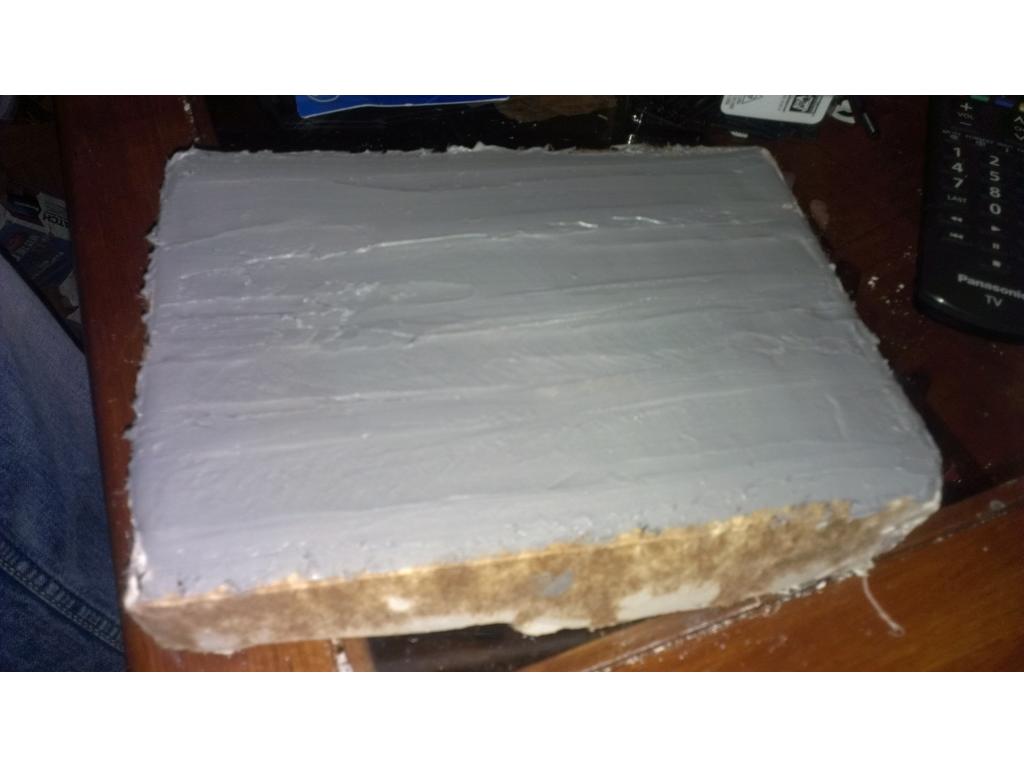
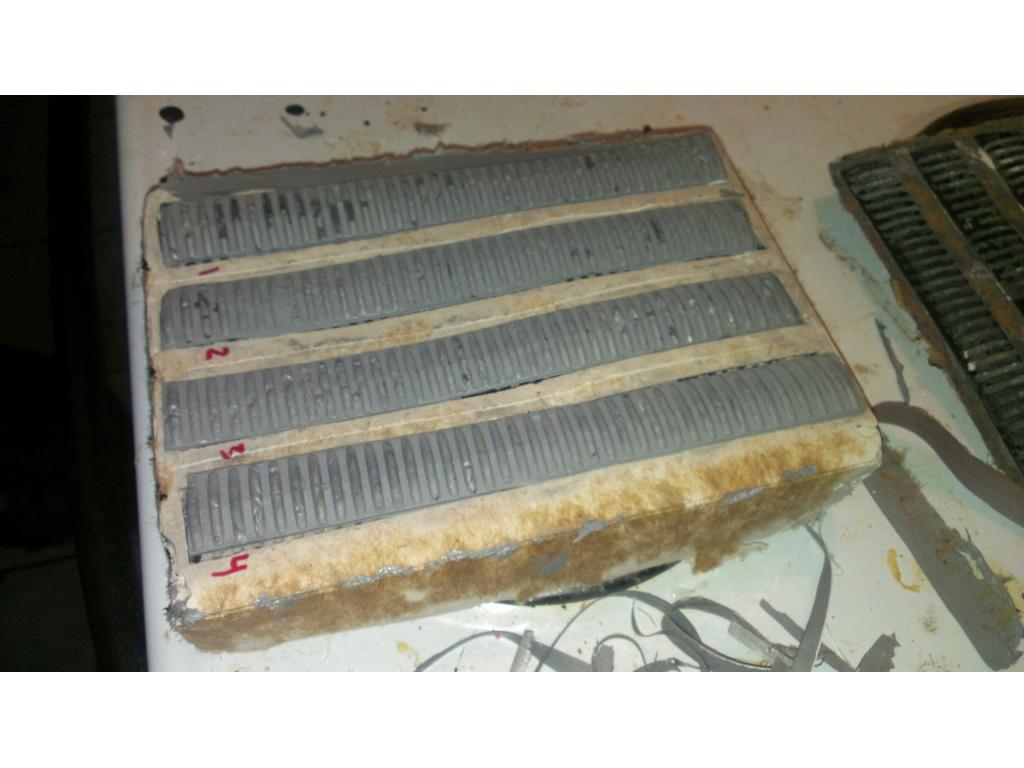
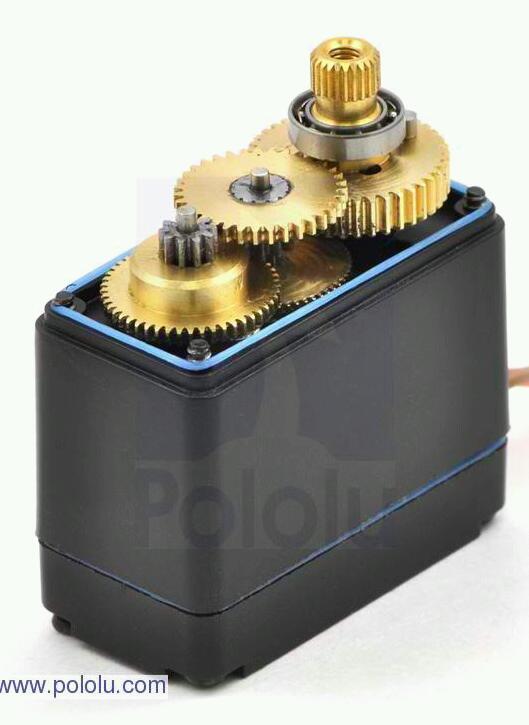
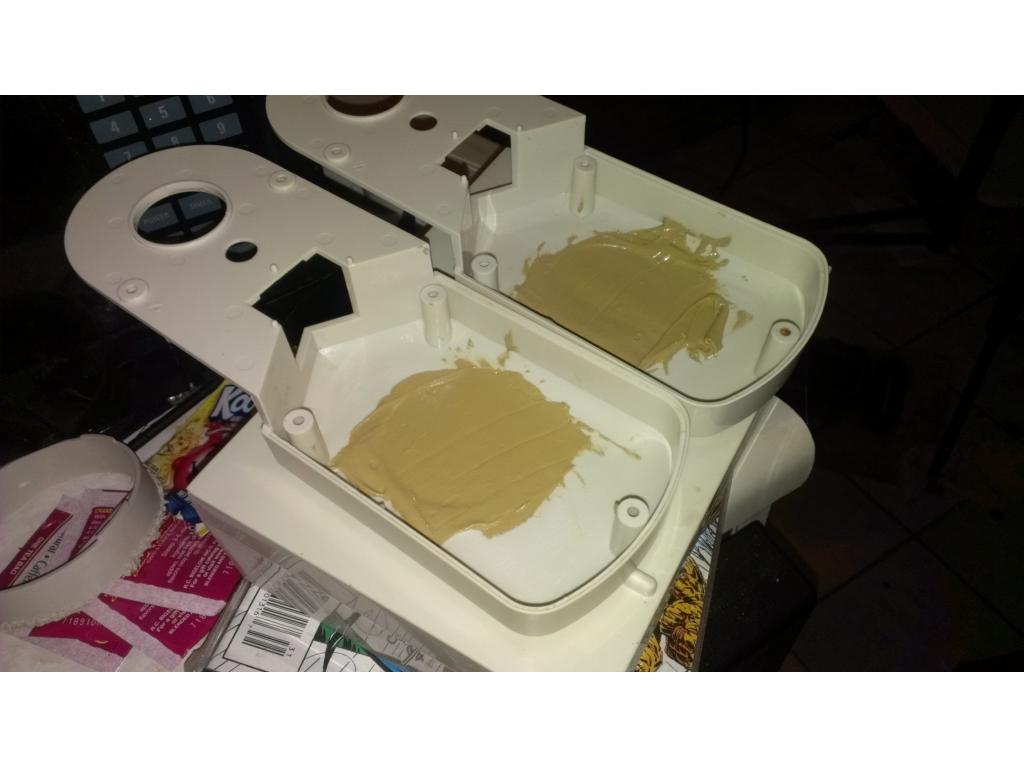
Trying to fill the gaps / where plastic leans in.Hey josh, have you looked at the planetary gear motors on Lynxmotion or the gear motors on Polulu?
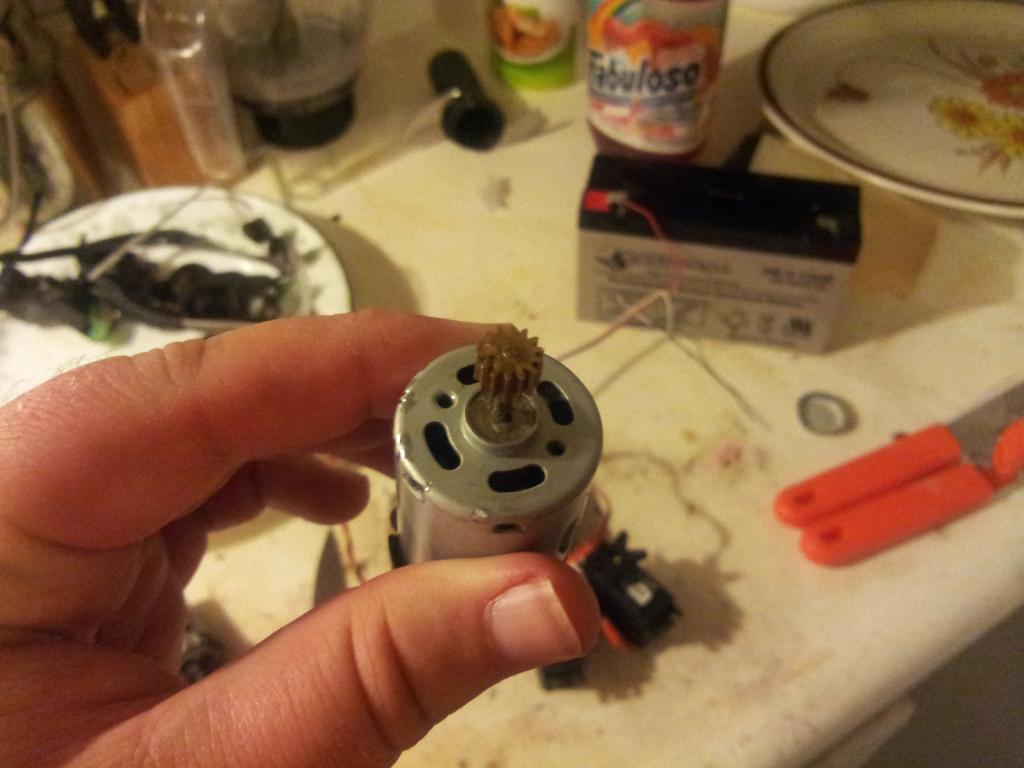
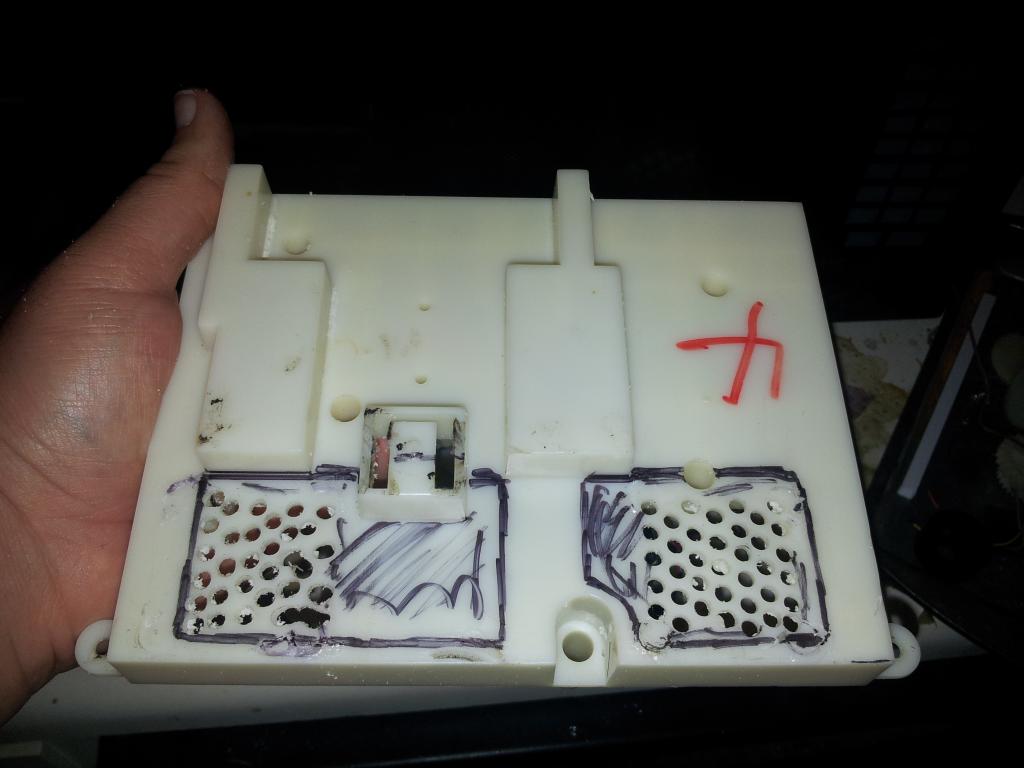
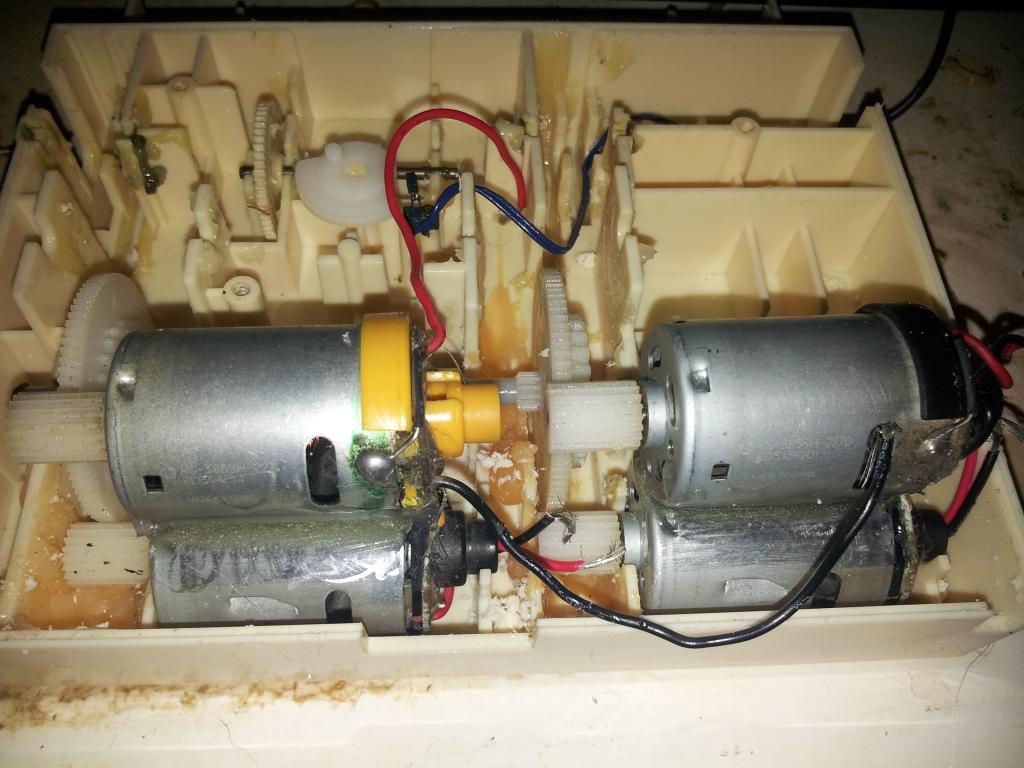
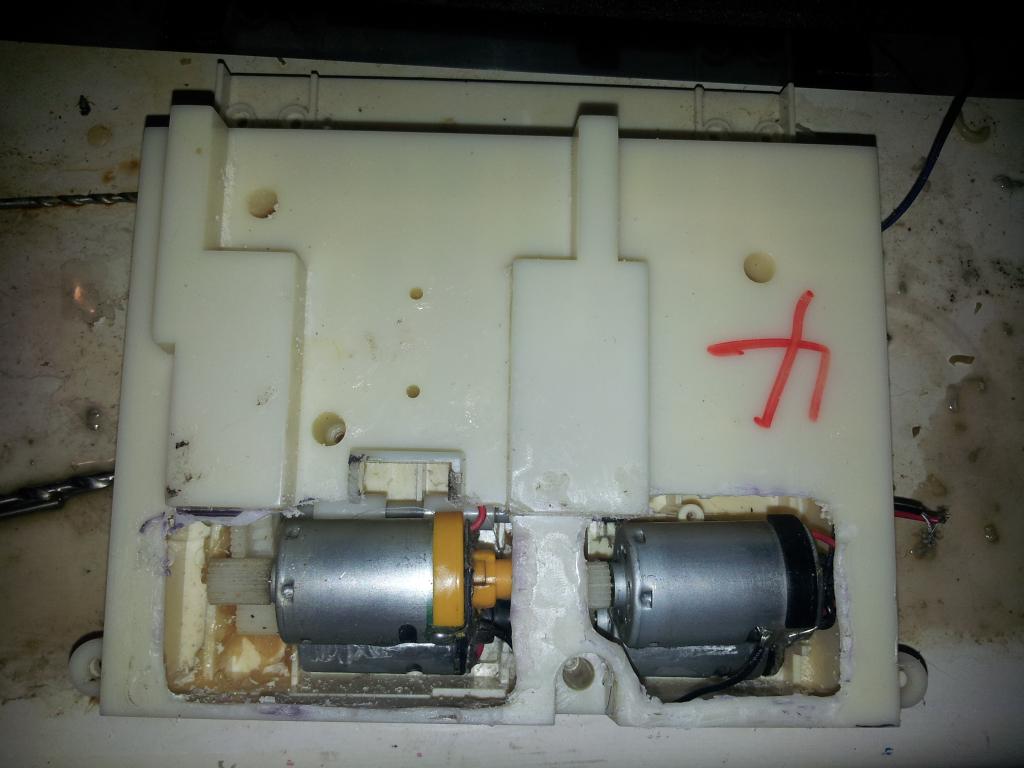
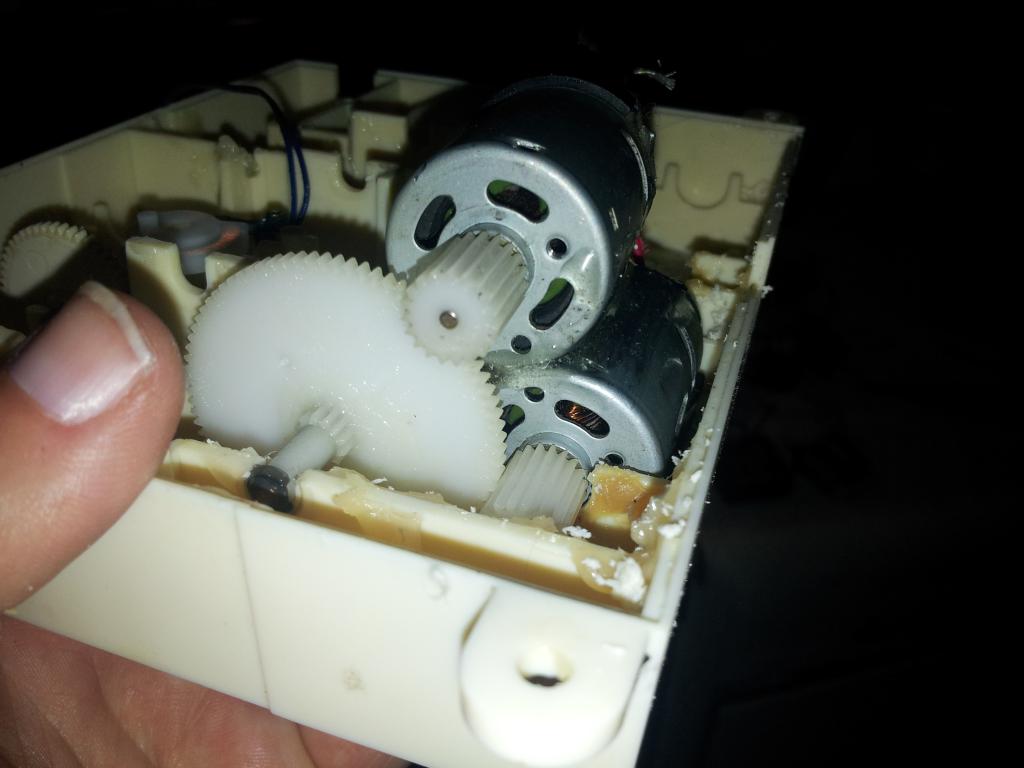
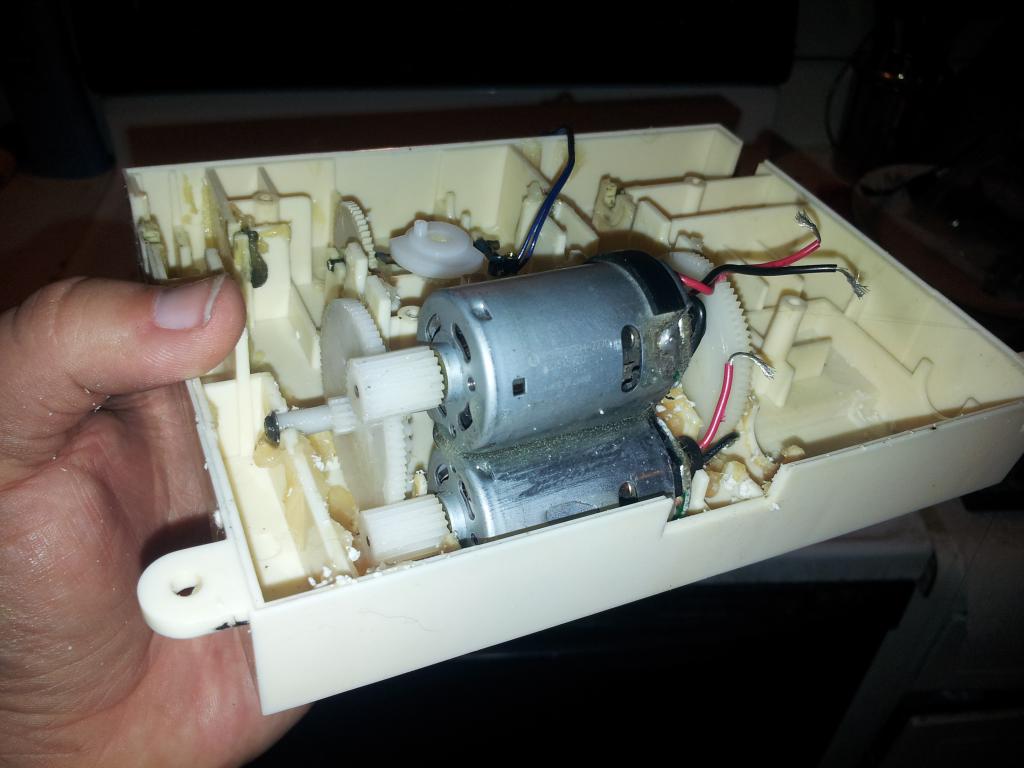
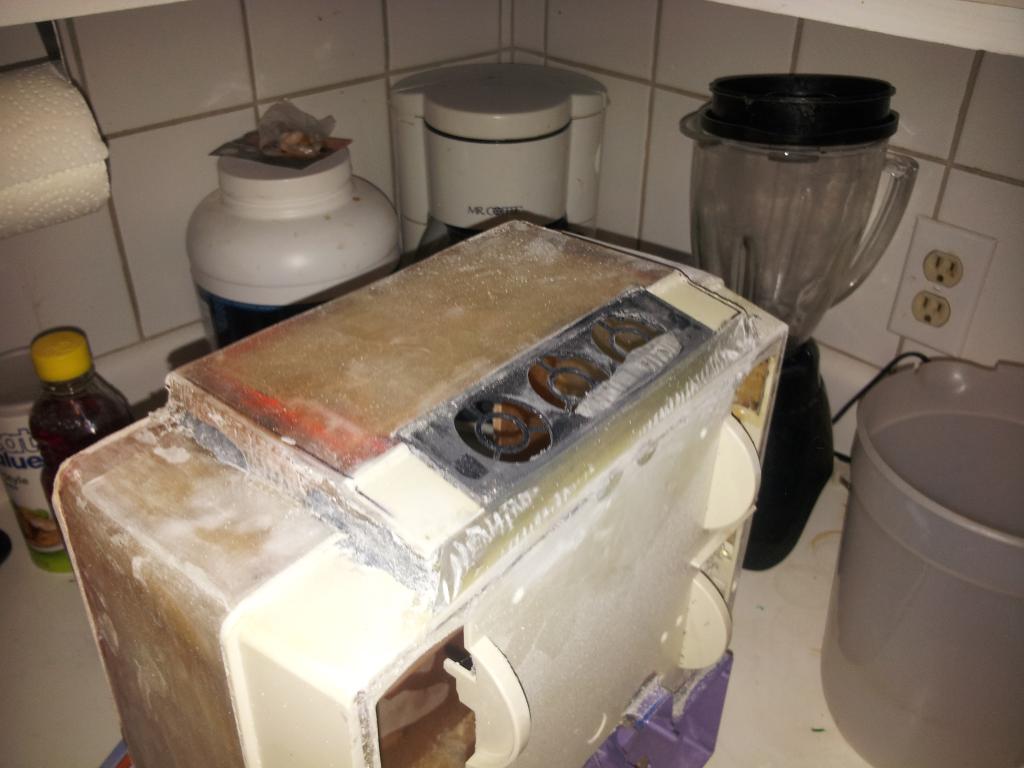
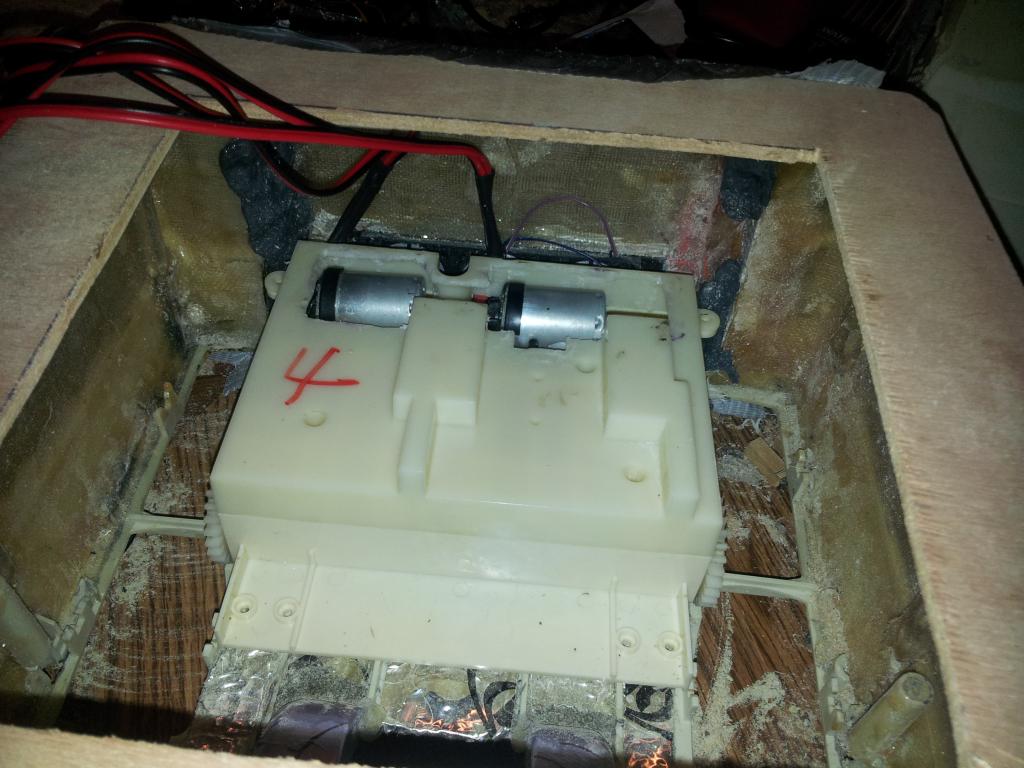
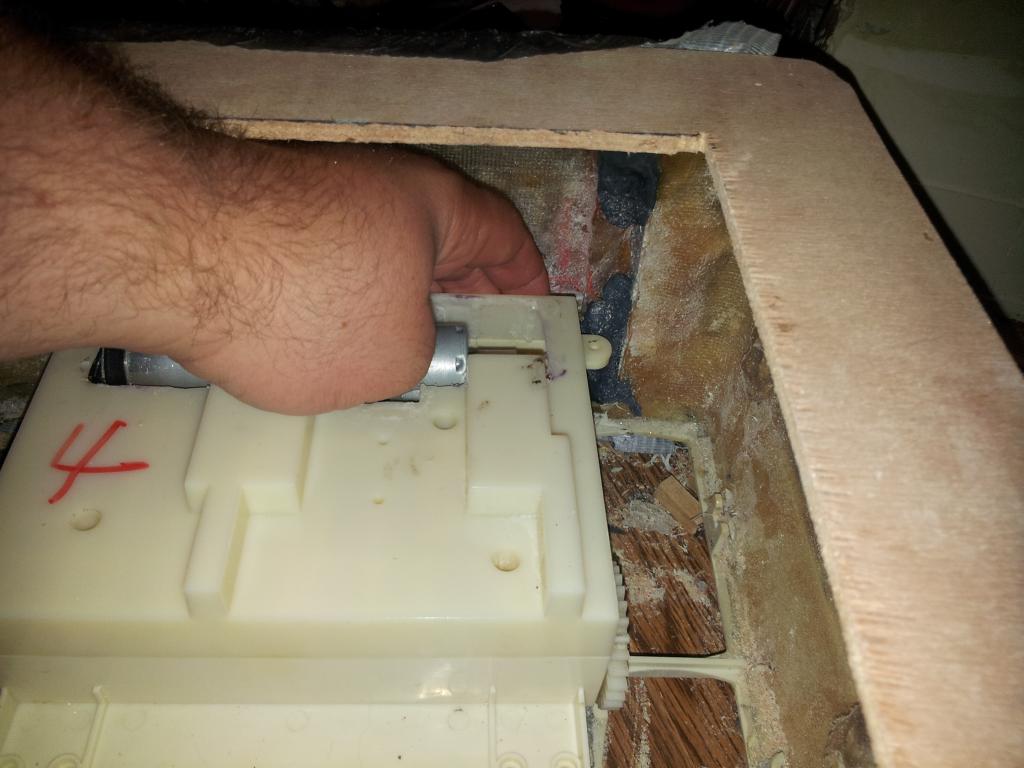
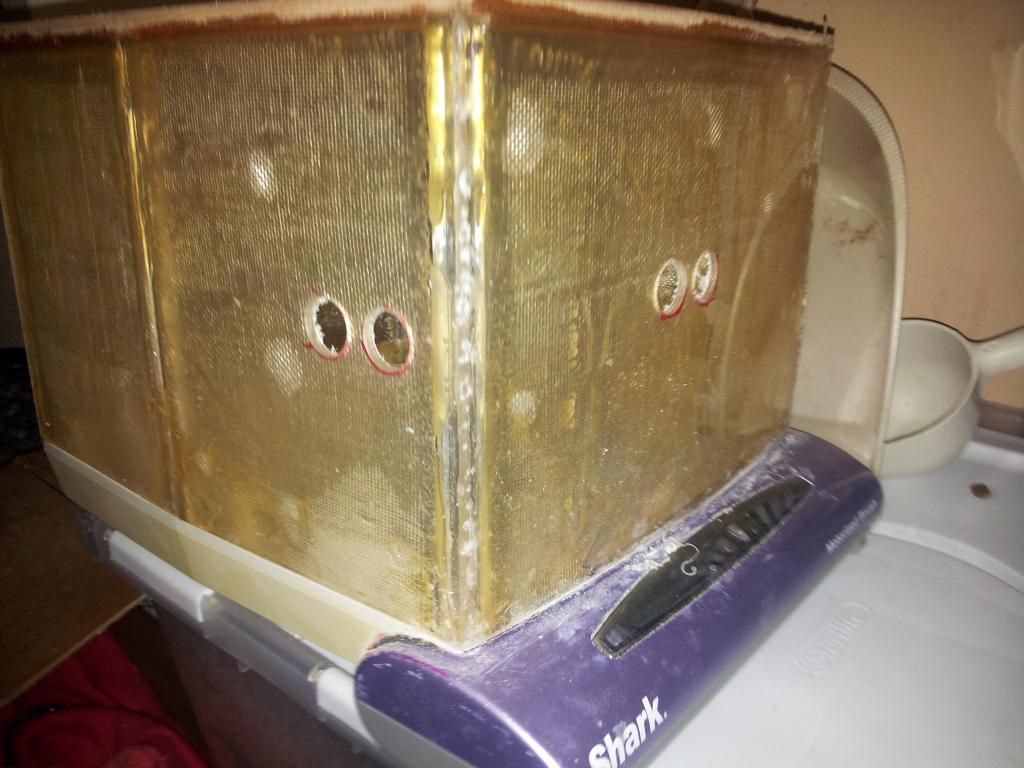
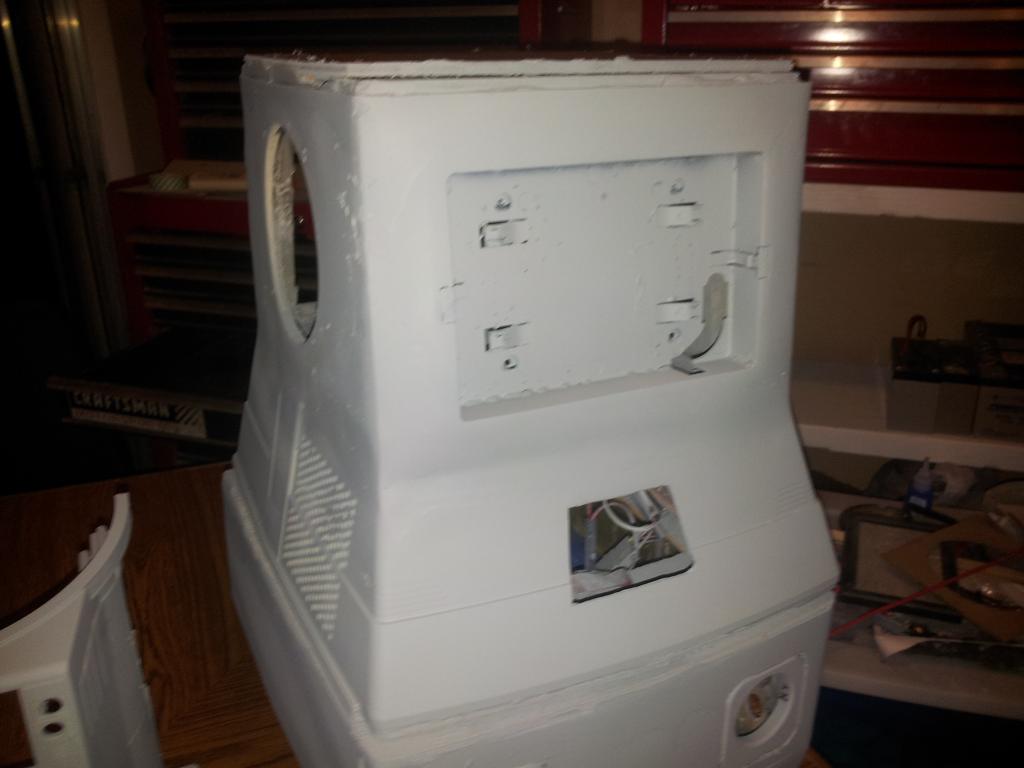
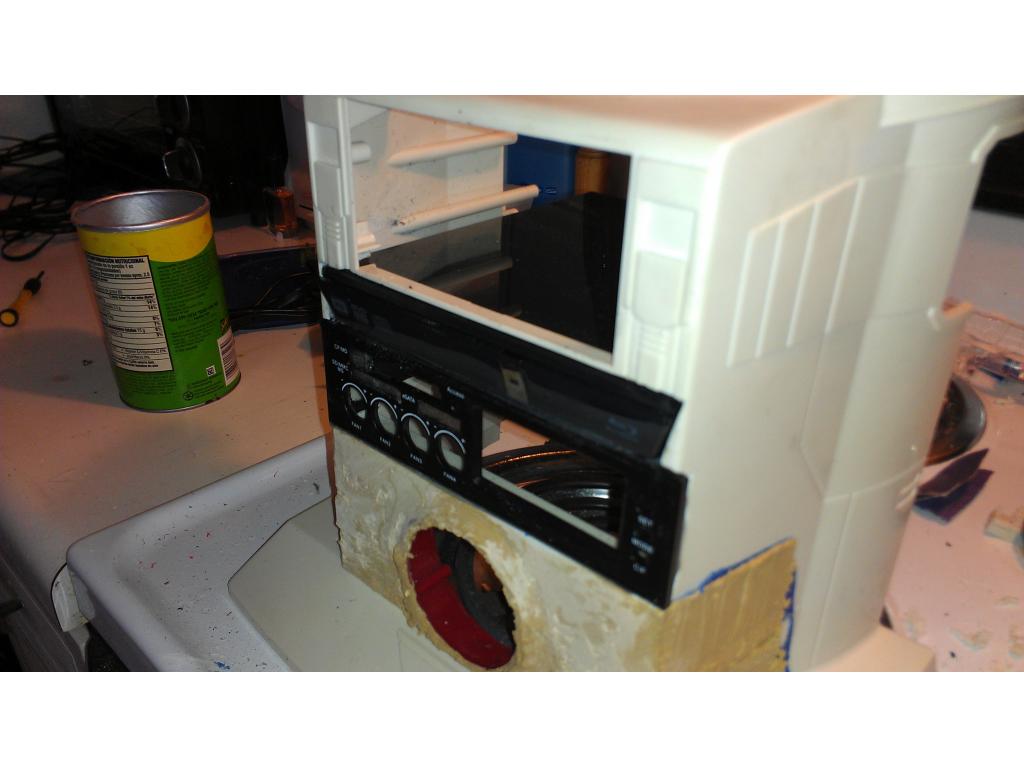
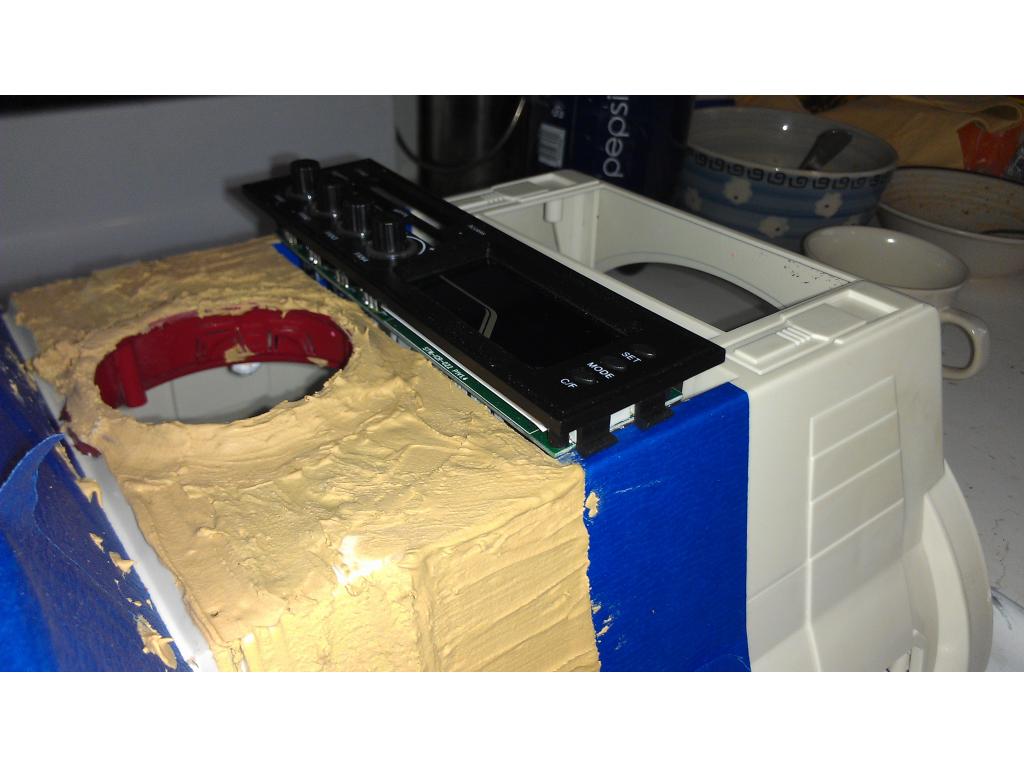
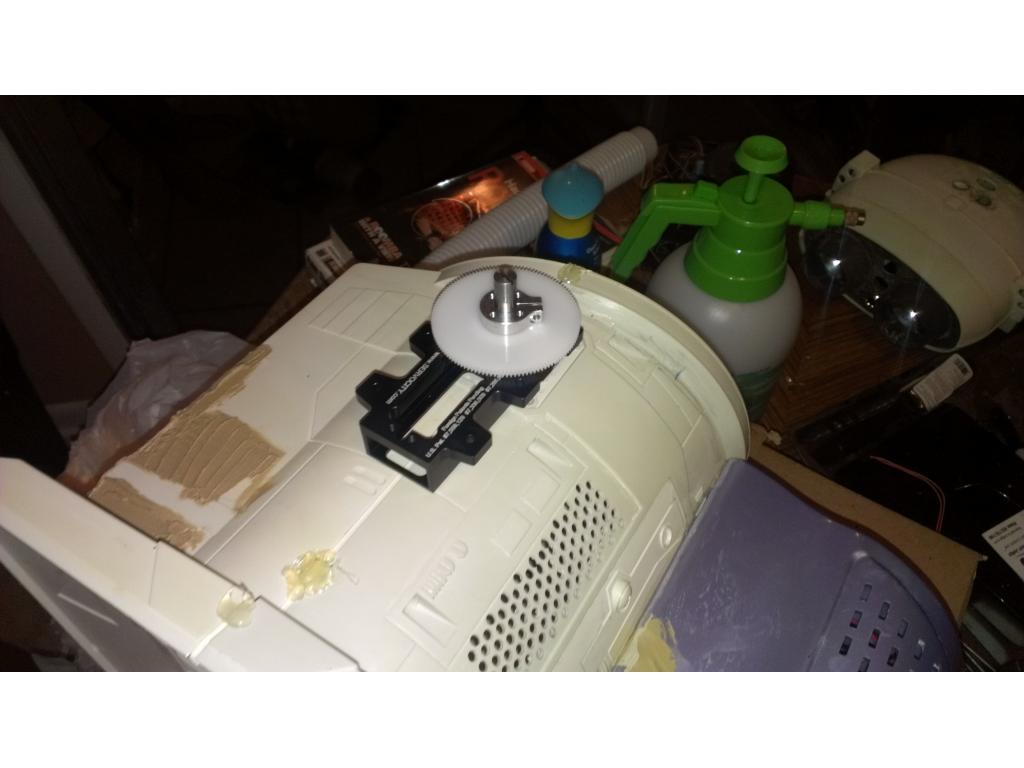
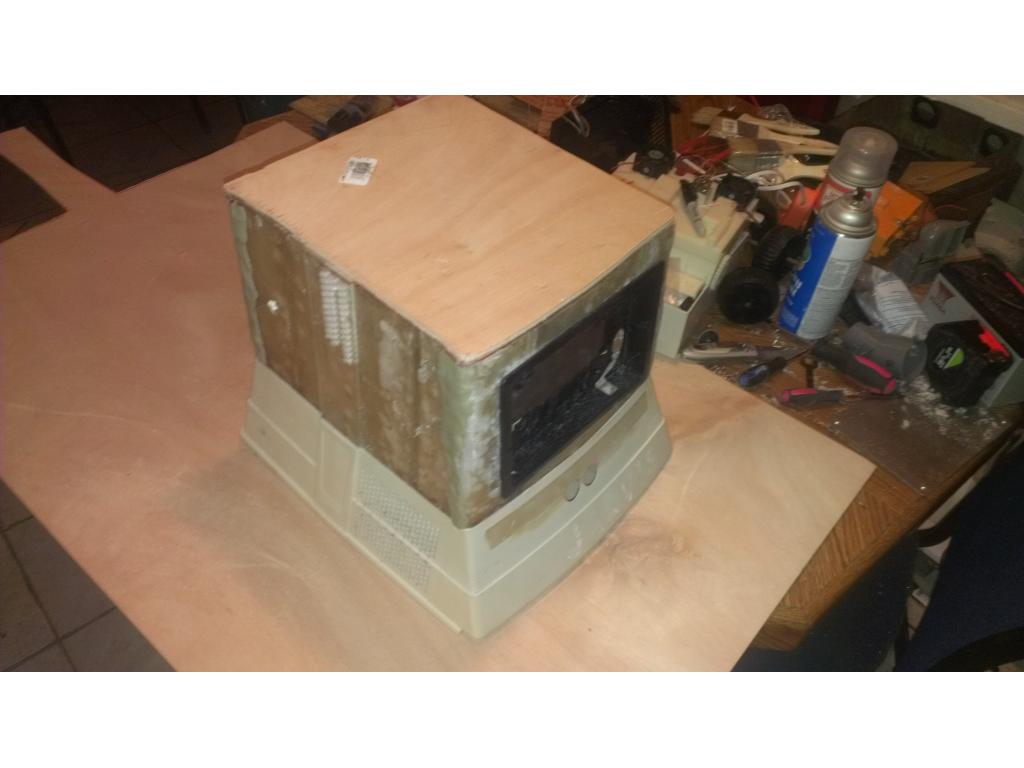
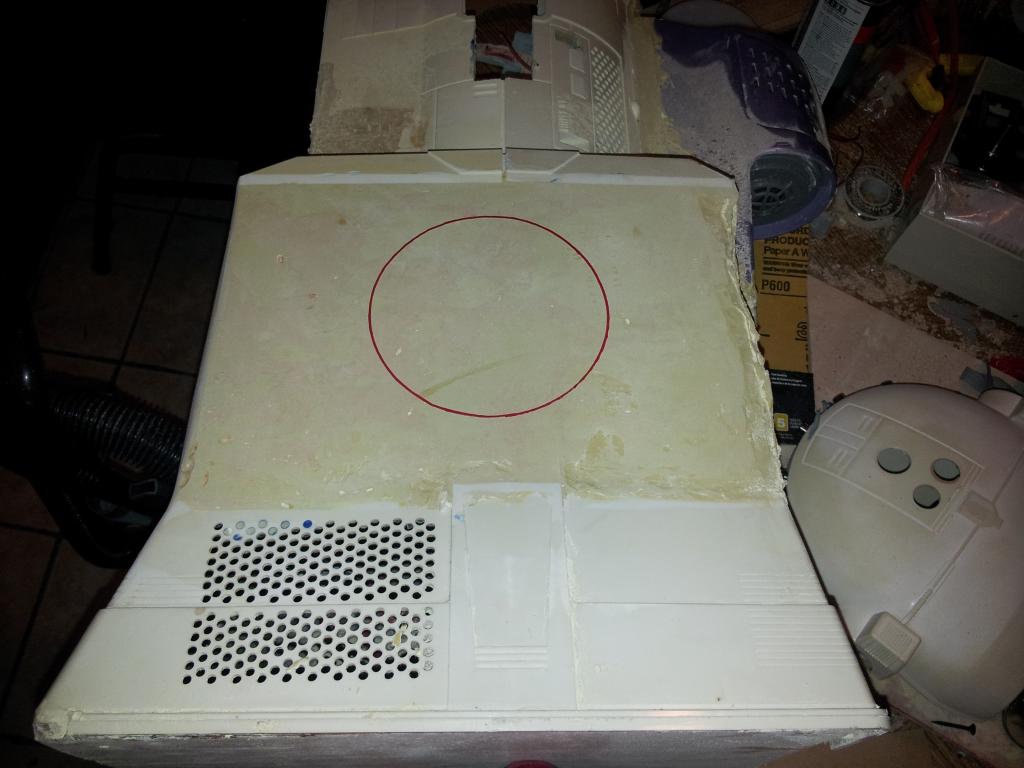
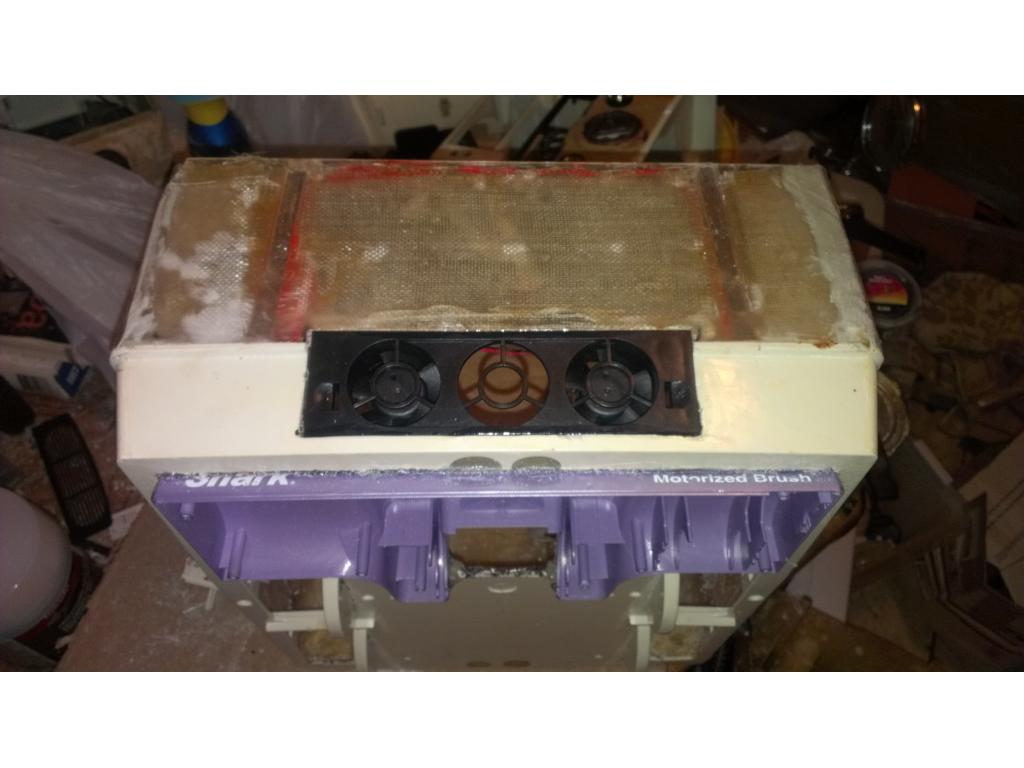
Not yet troy , I'm thinking I might be able to use the stock gearbox with some cutting but right now getting the outside fixed up. I've been filling each side of the top riser to get it flush.
Ok man. I'm sure you can figure a solution.
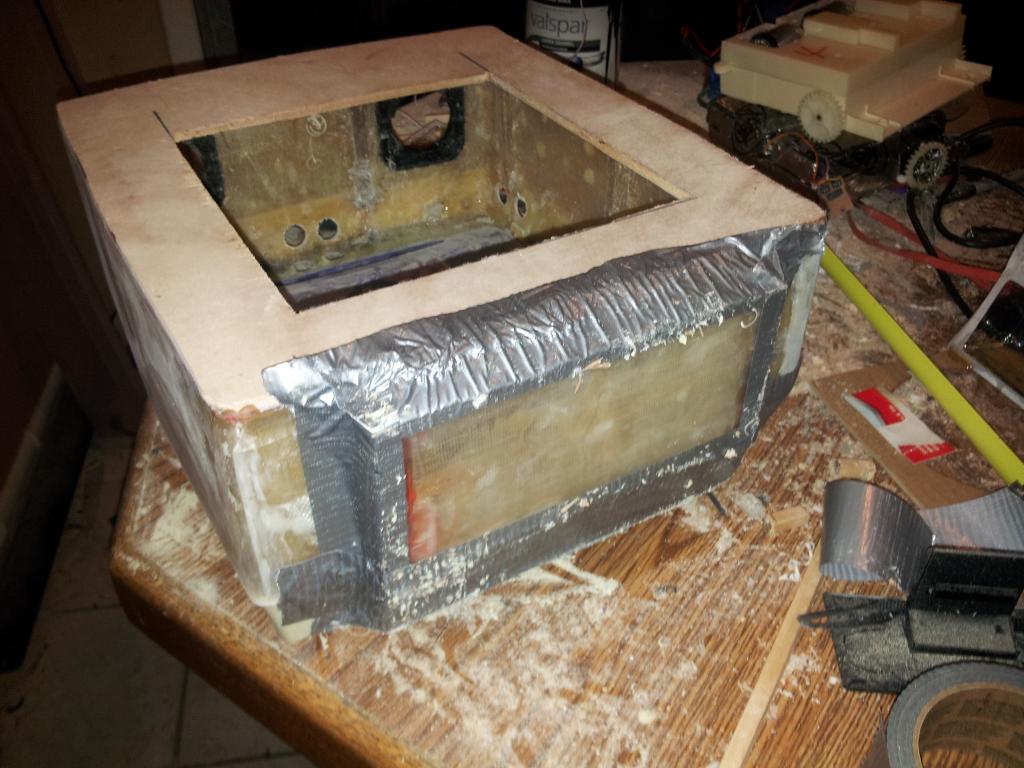
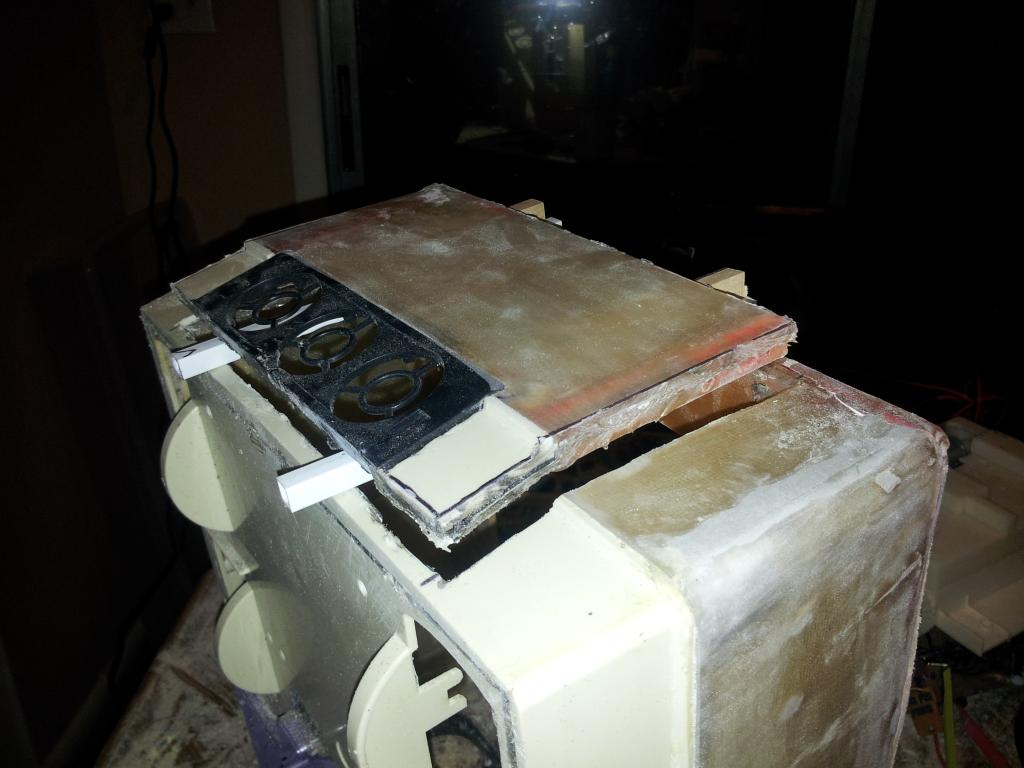
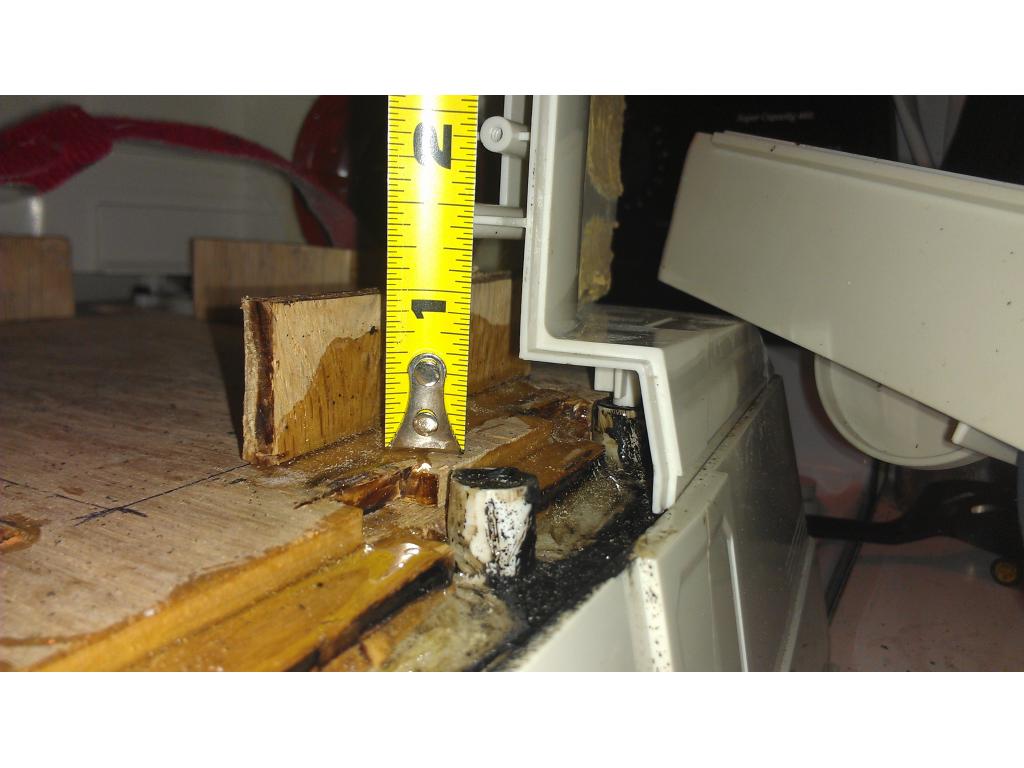
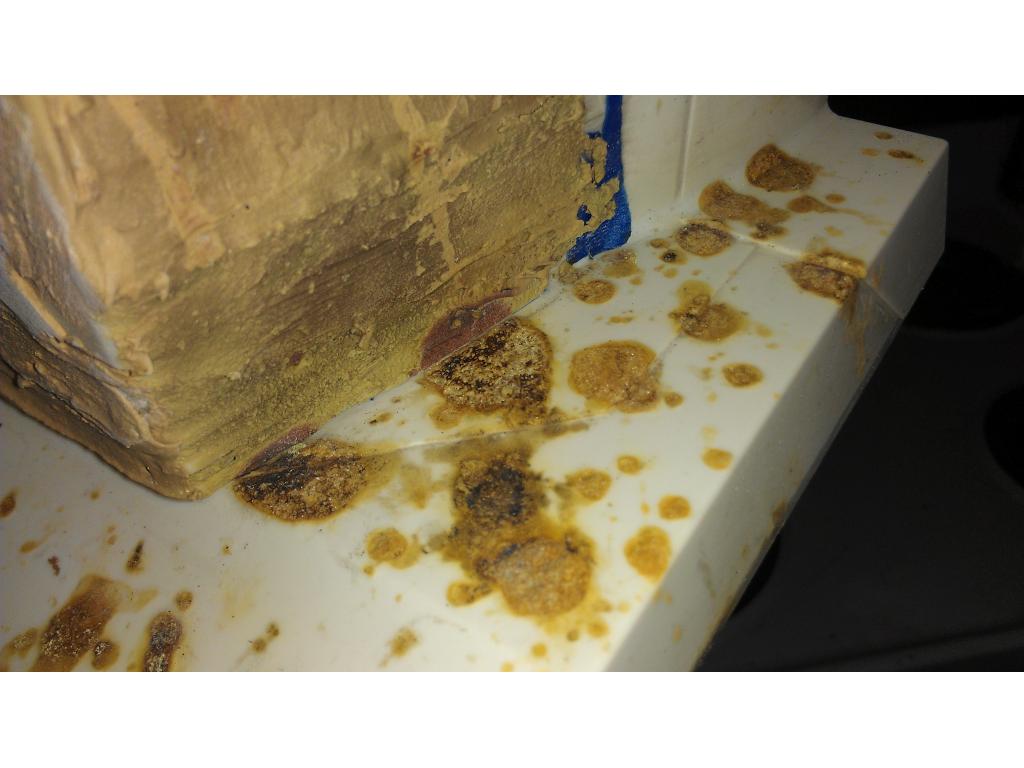
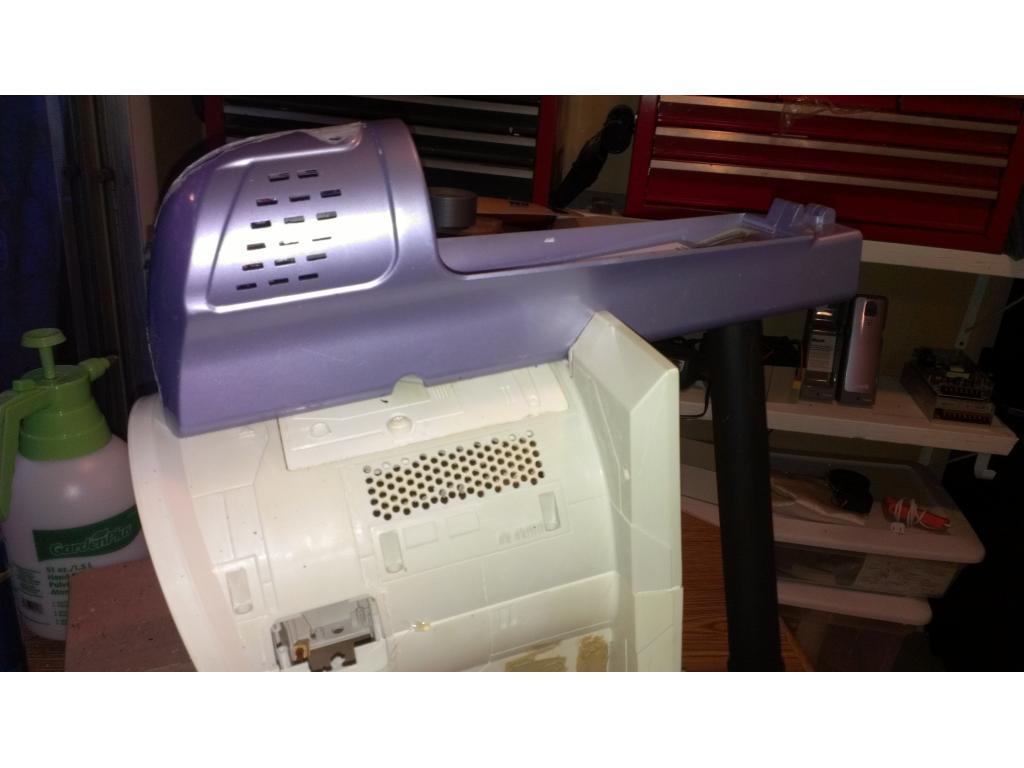
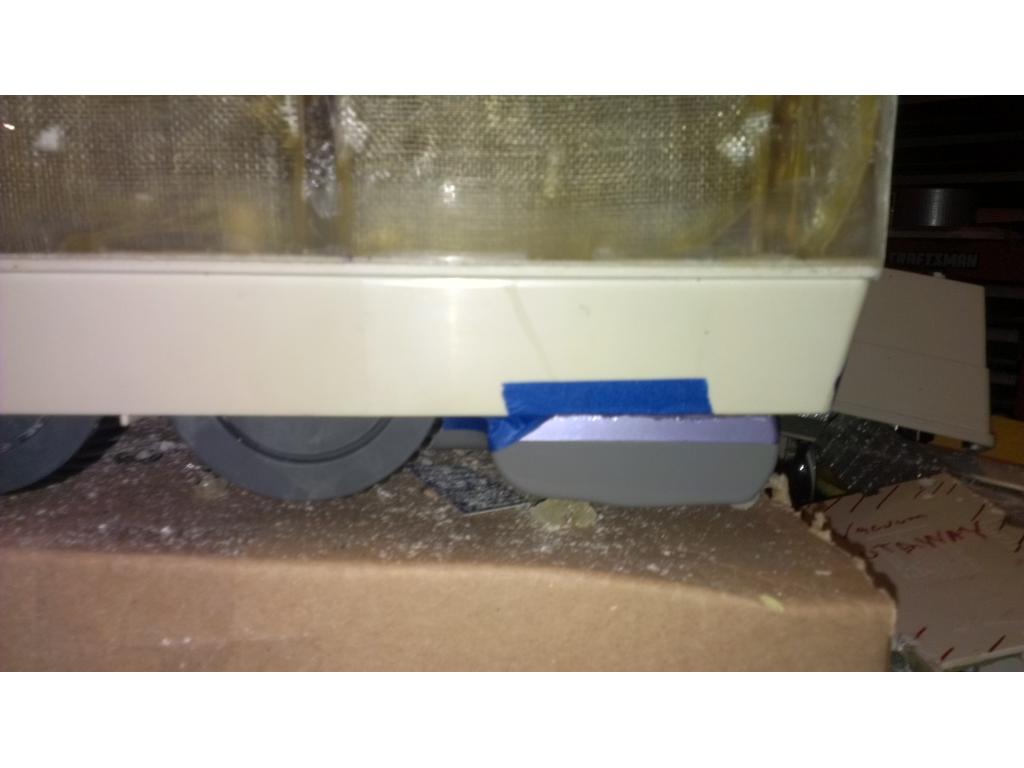
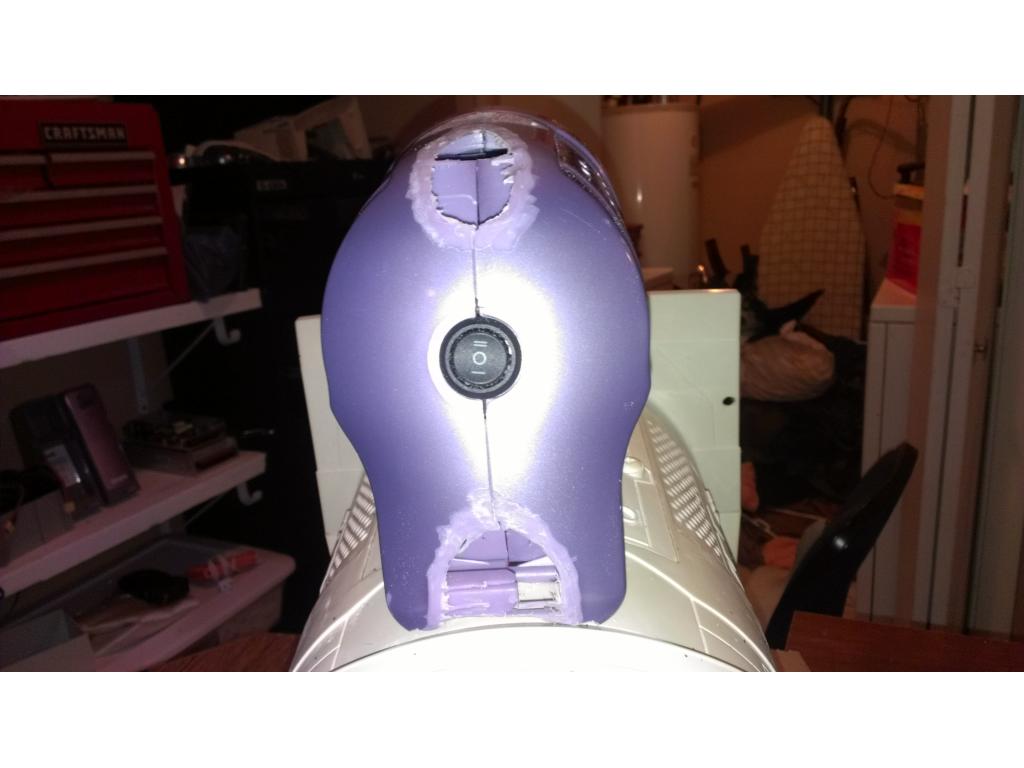
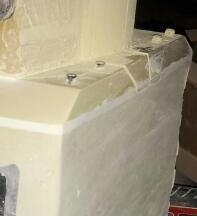
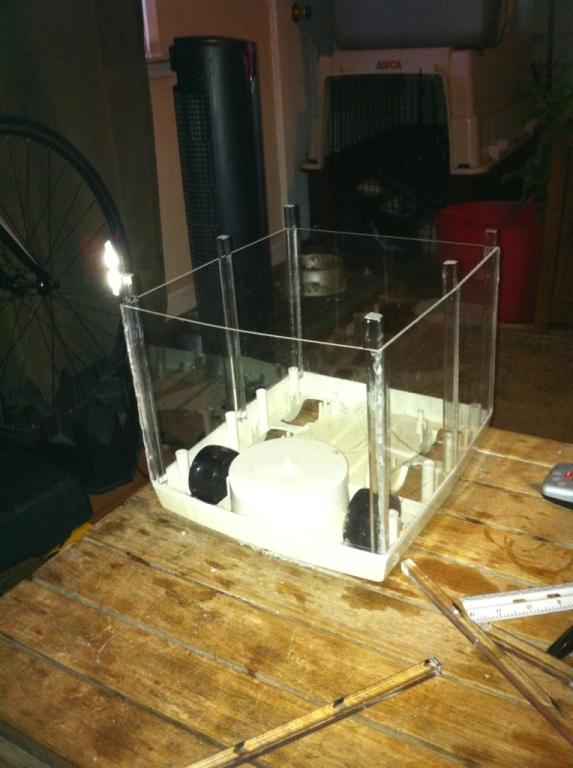
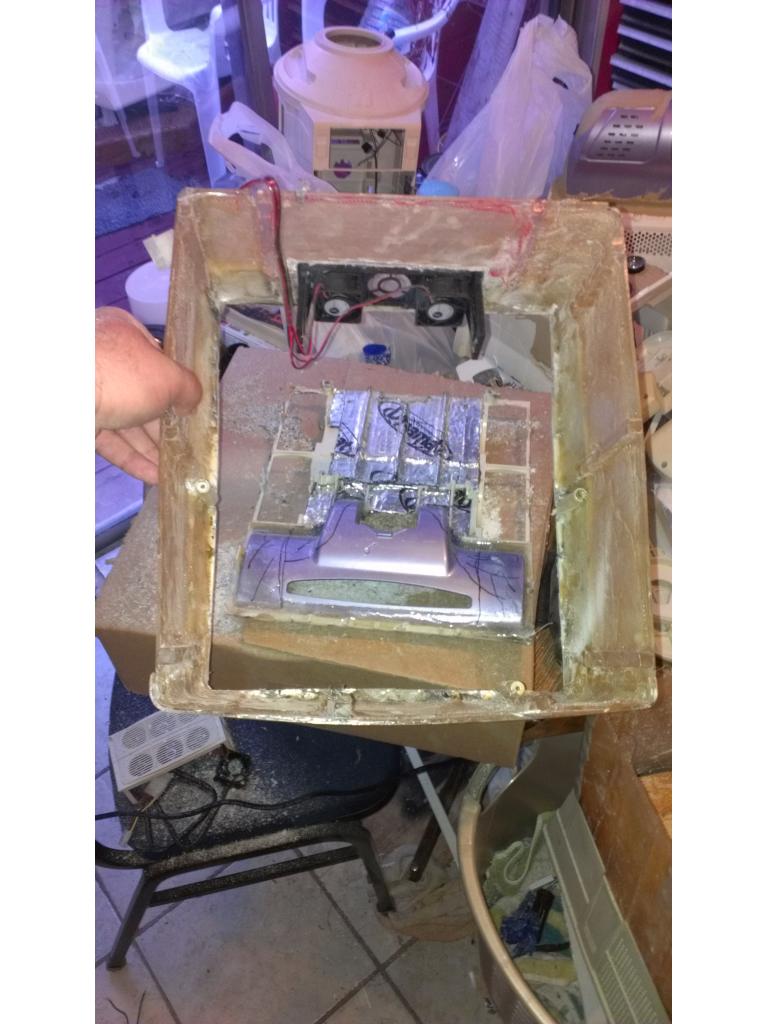
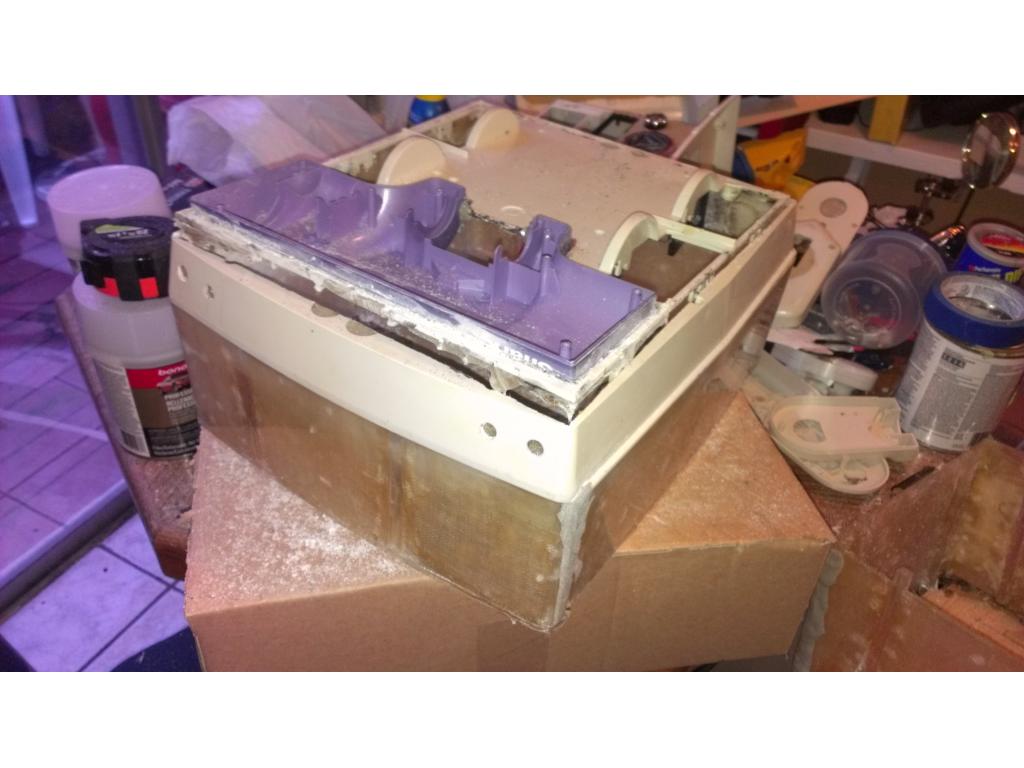
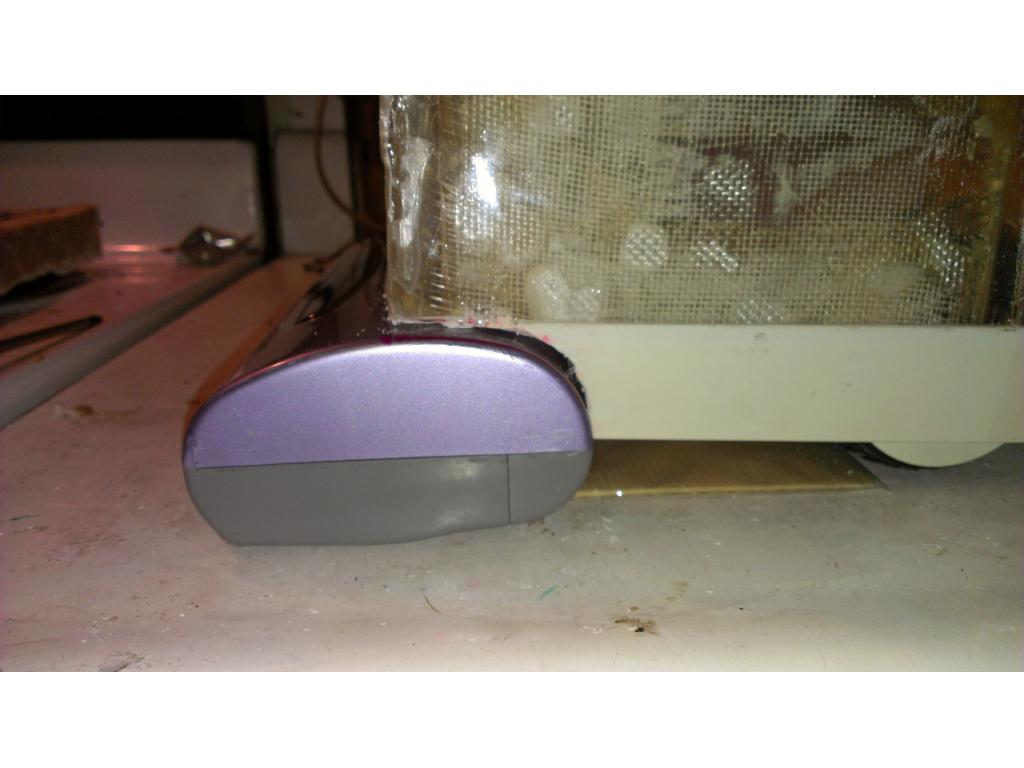
Here is a before pic so you can see the gap and how far the edge of the torso is from the riser.
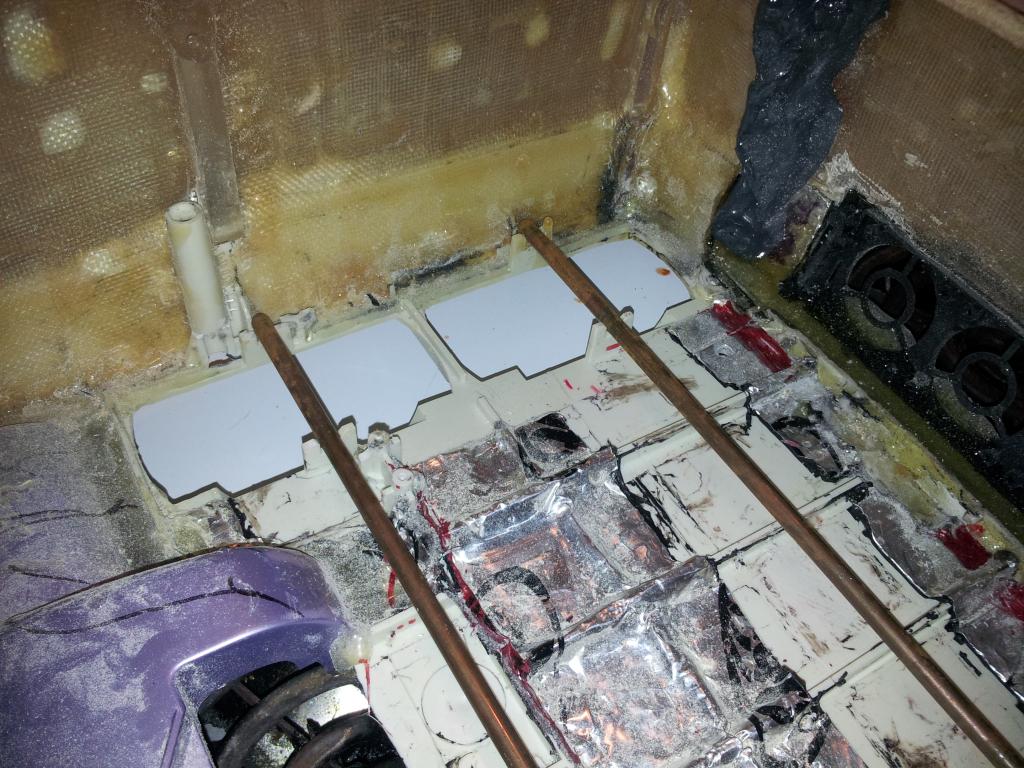
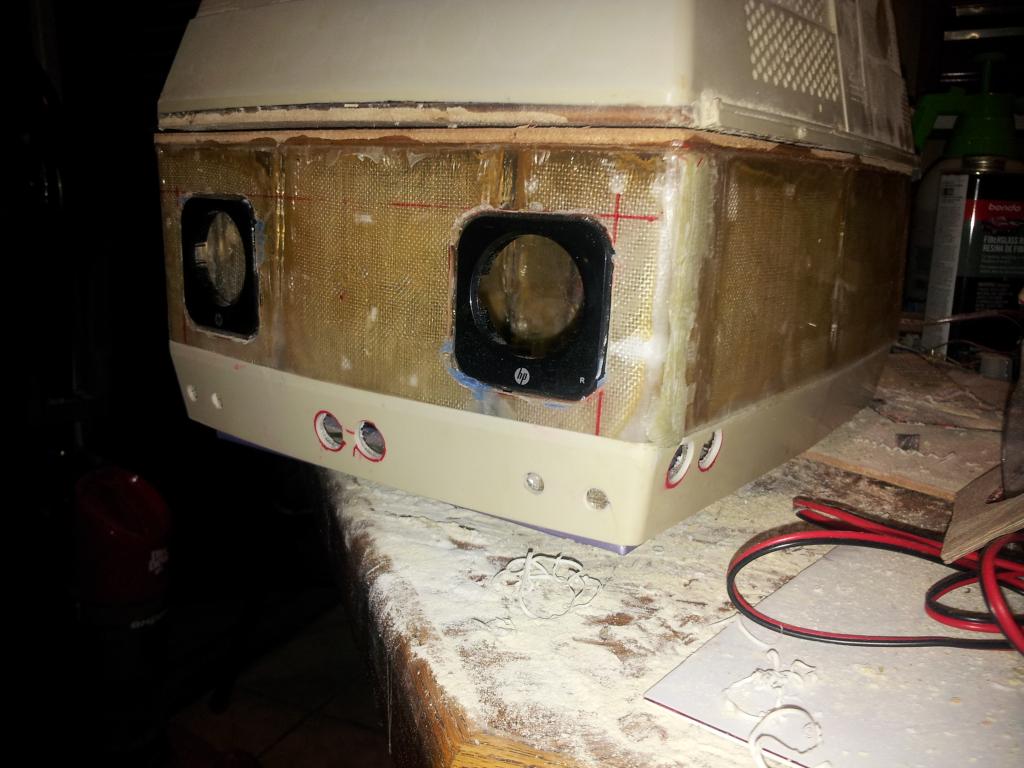
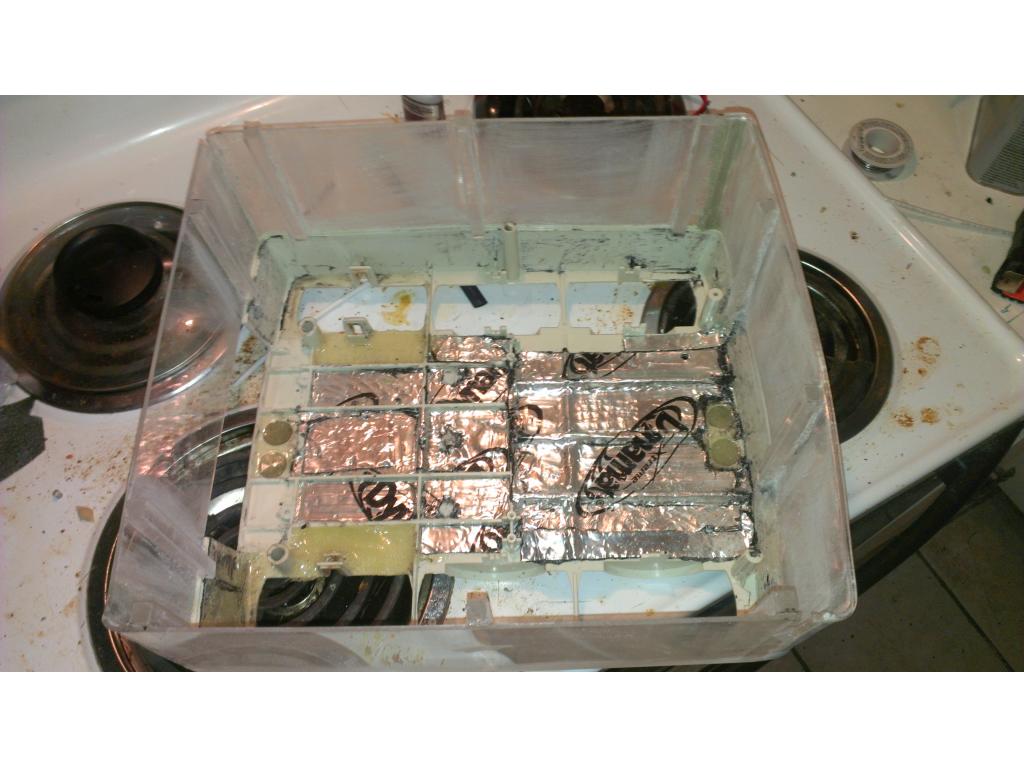
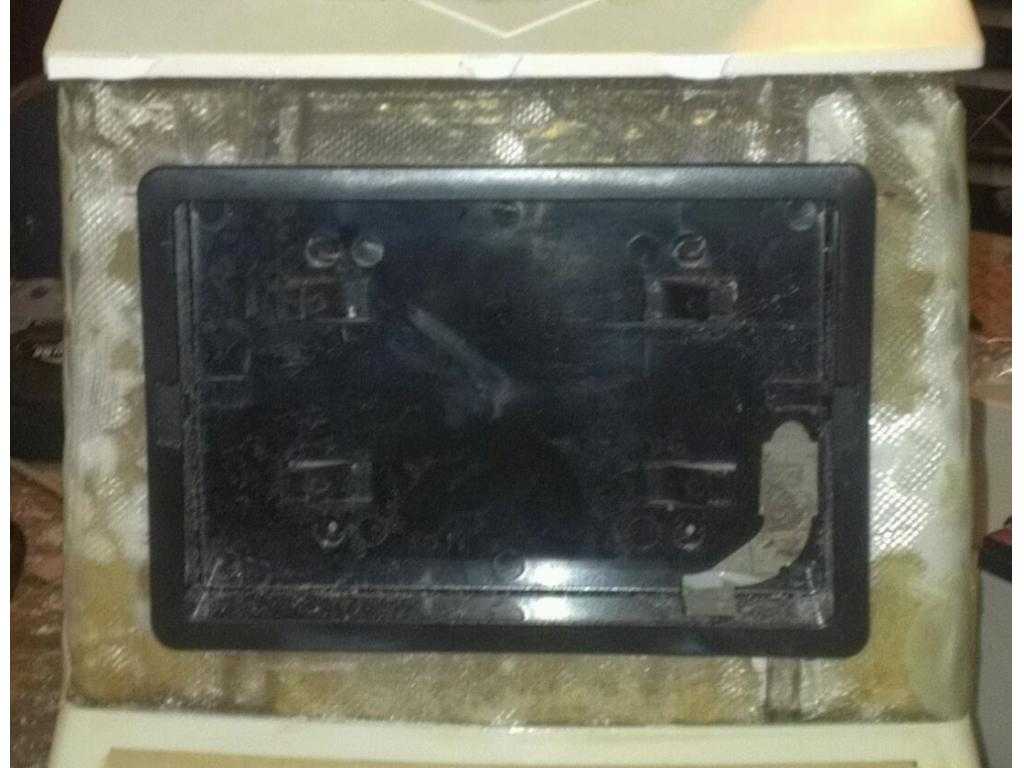
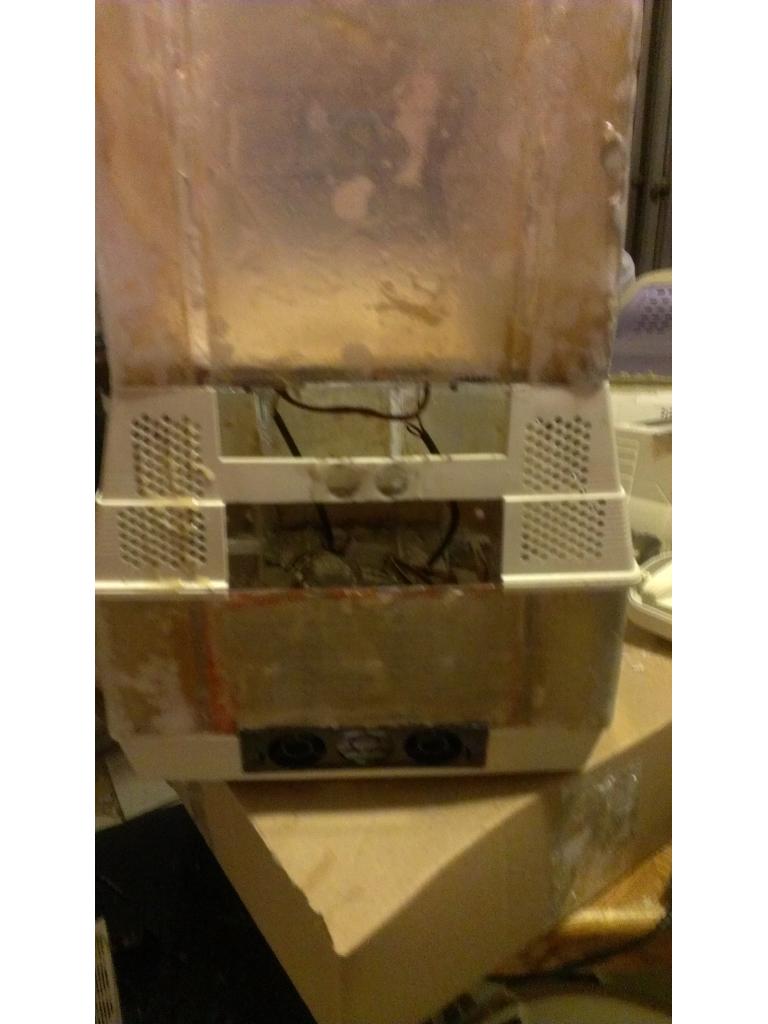
One side its about 1/4 inch difference and other side about 1/8 off. The rear was the biggest difference of 1/2 inch. The filler is heavy so once I get the outside straight I will need to cut away the inside fiberglass and probably the Plexiglas then reapply a couple thin layers of fiberglass agian. I don't need to do that anytime soon but I can lighten it up 3 to 5 pounds by doing that later.
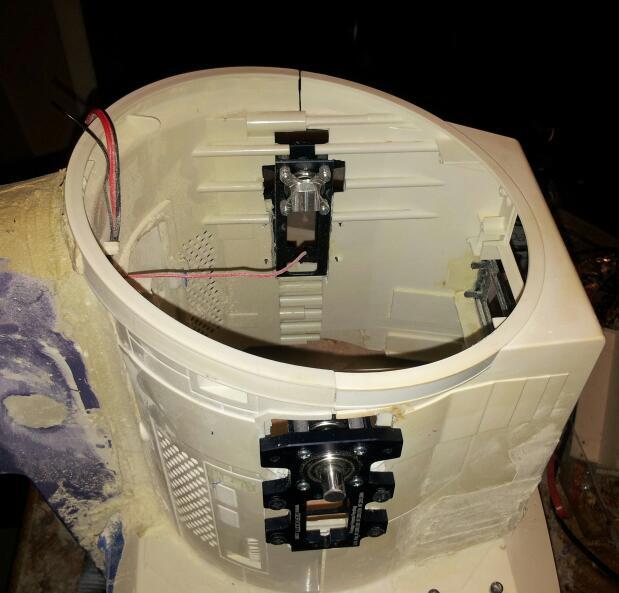
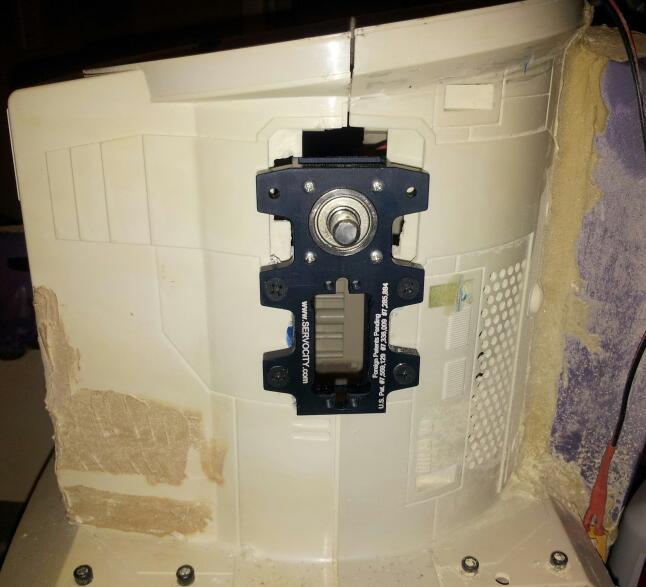
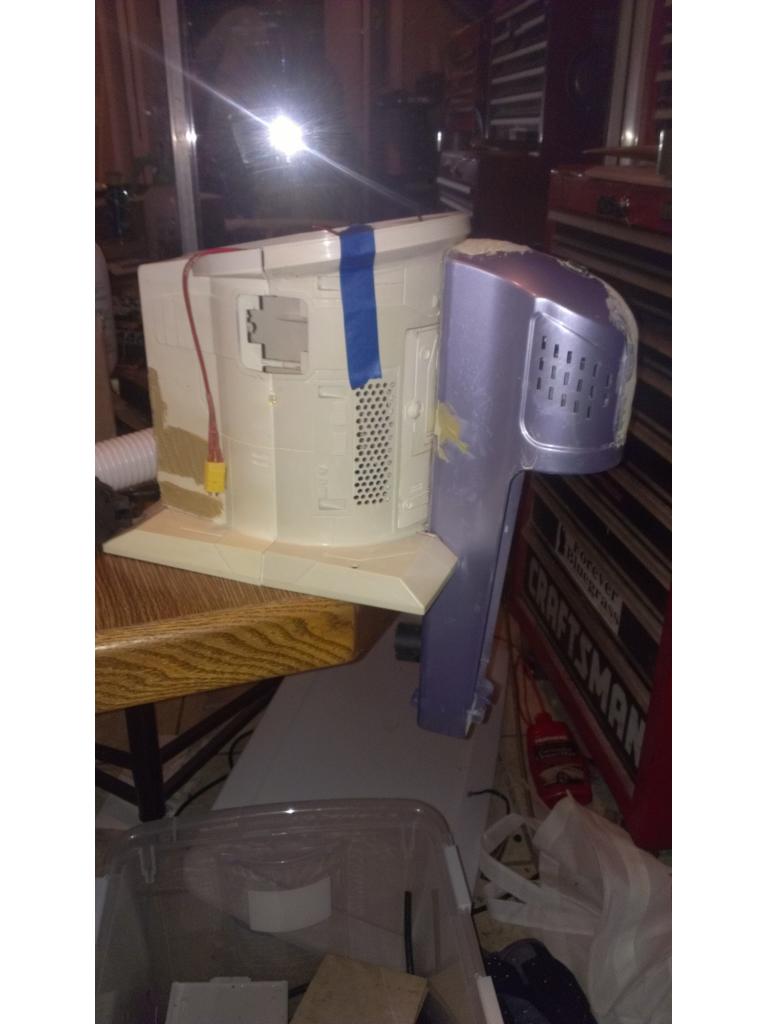
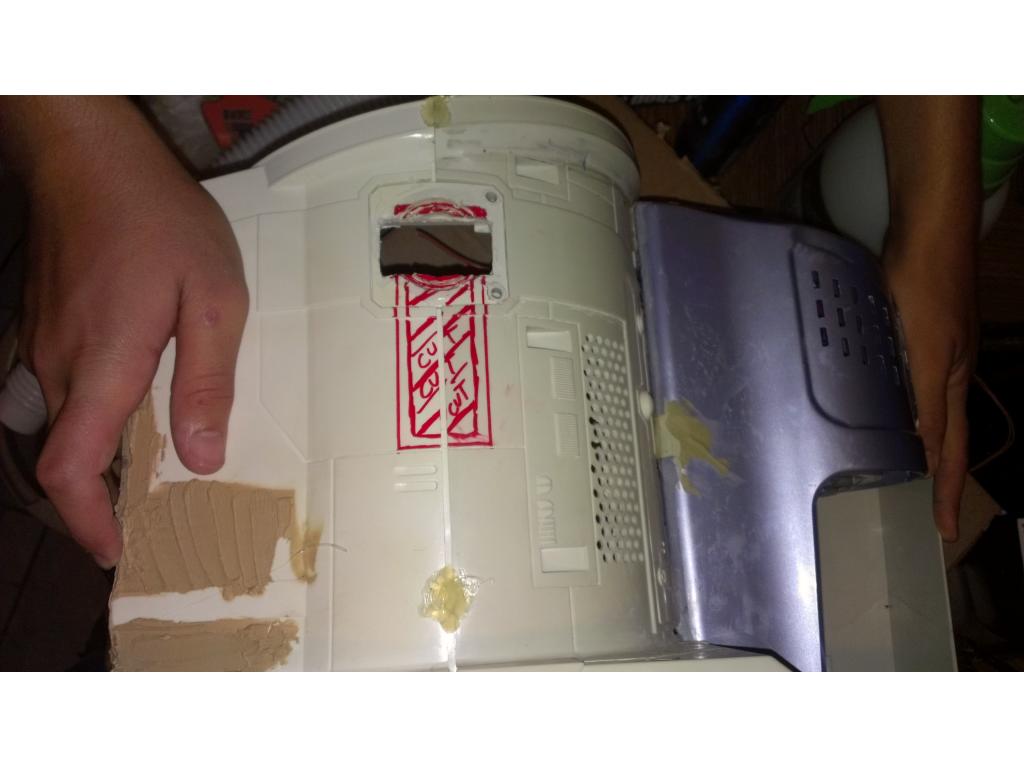
I did drill the torso mounting holes so this cannot move around while working on it.
8 hex bolts go from the outside through the deck and the top of the riser.

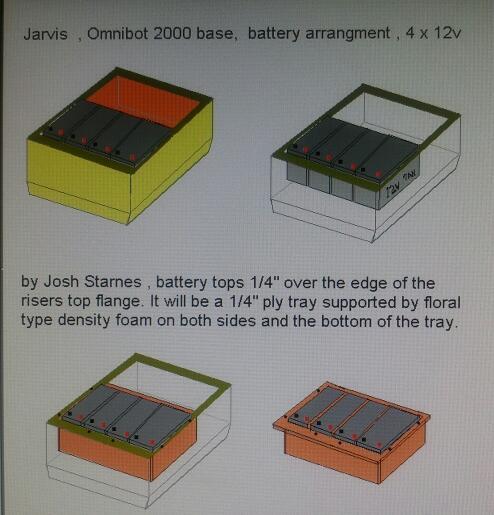
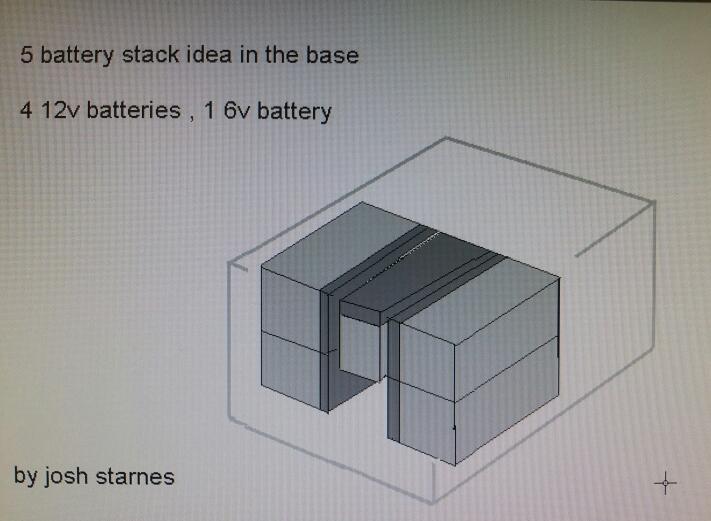
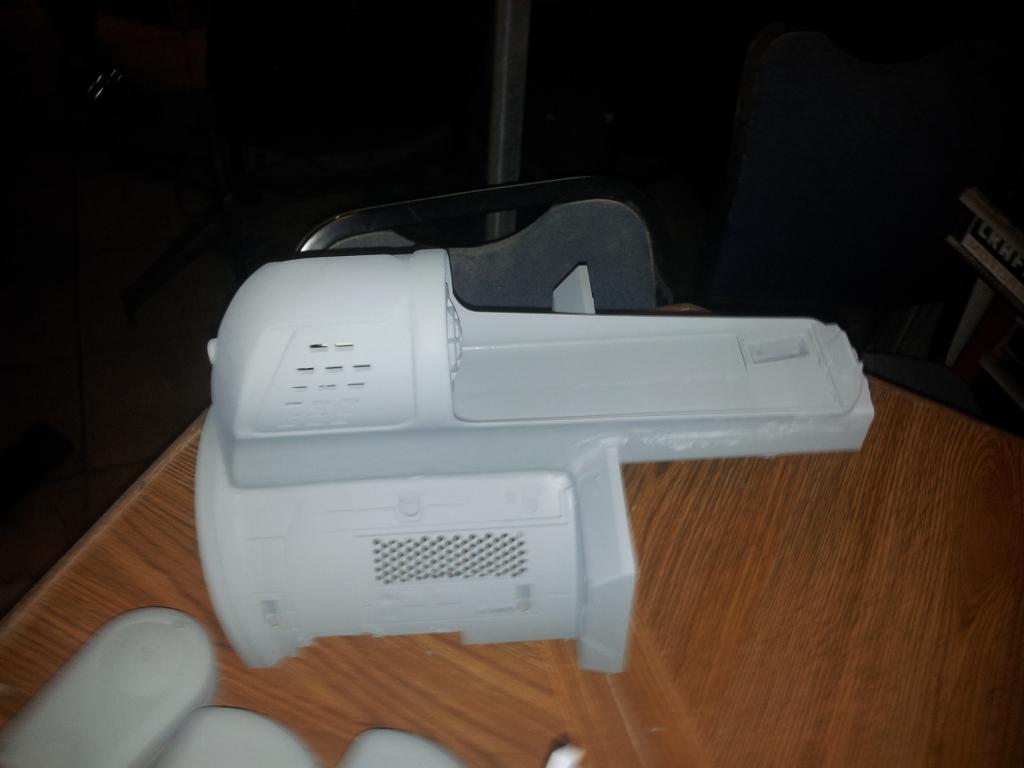
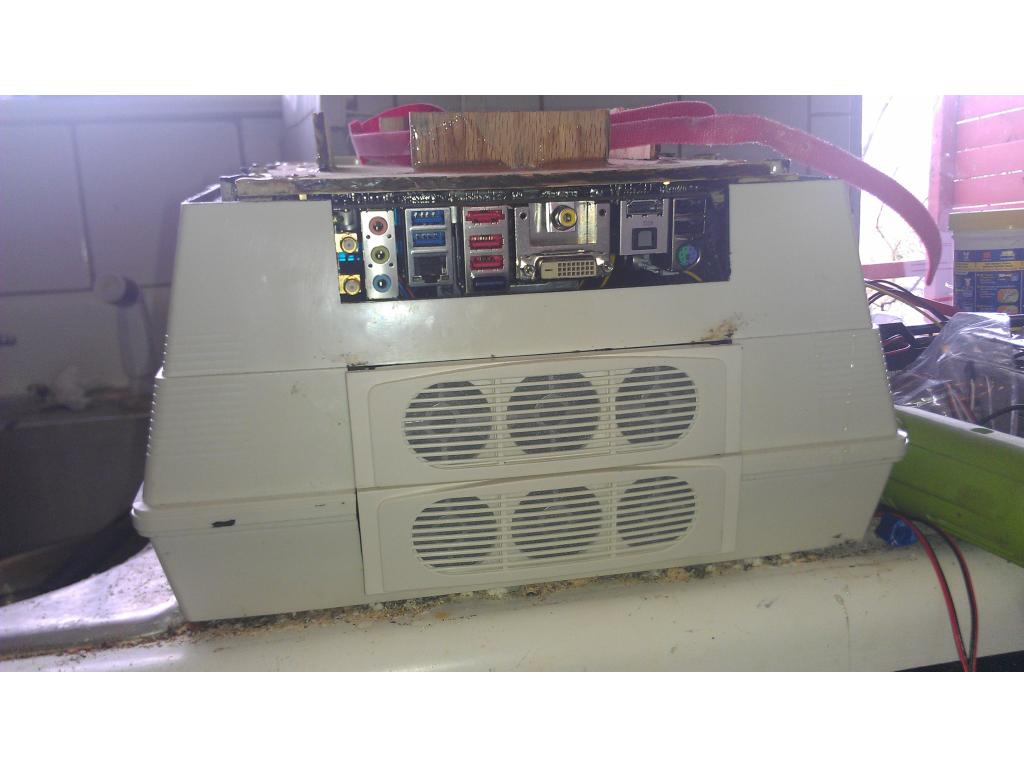
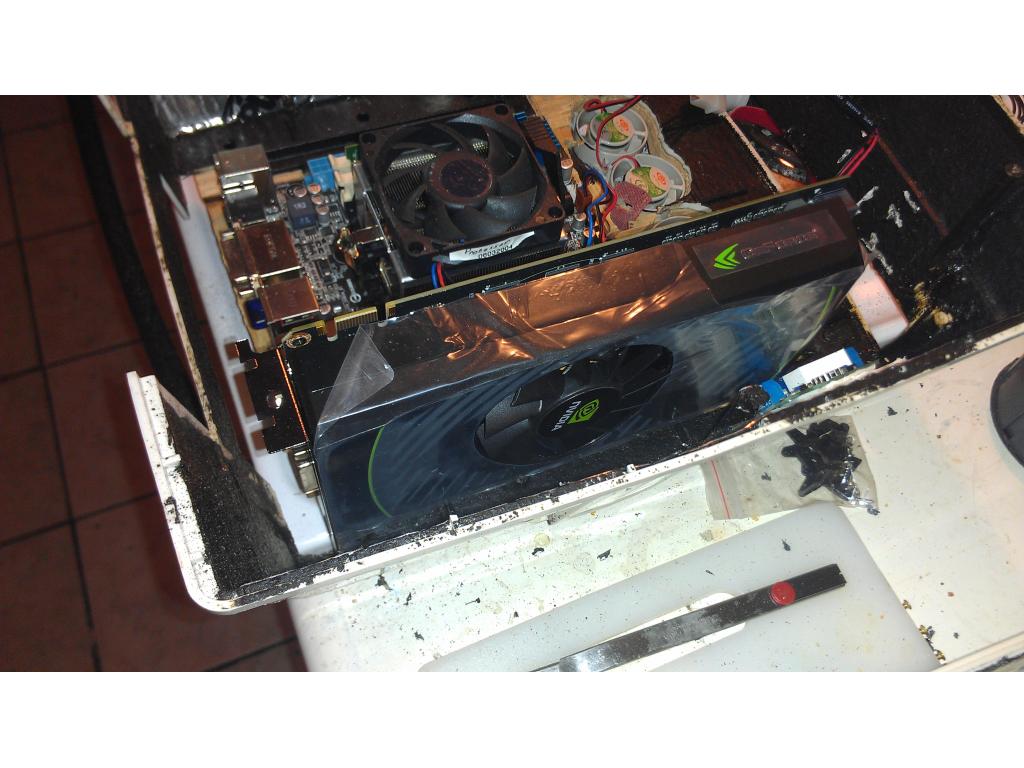
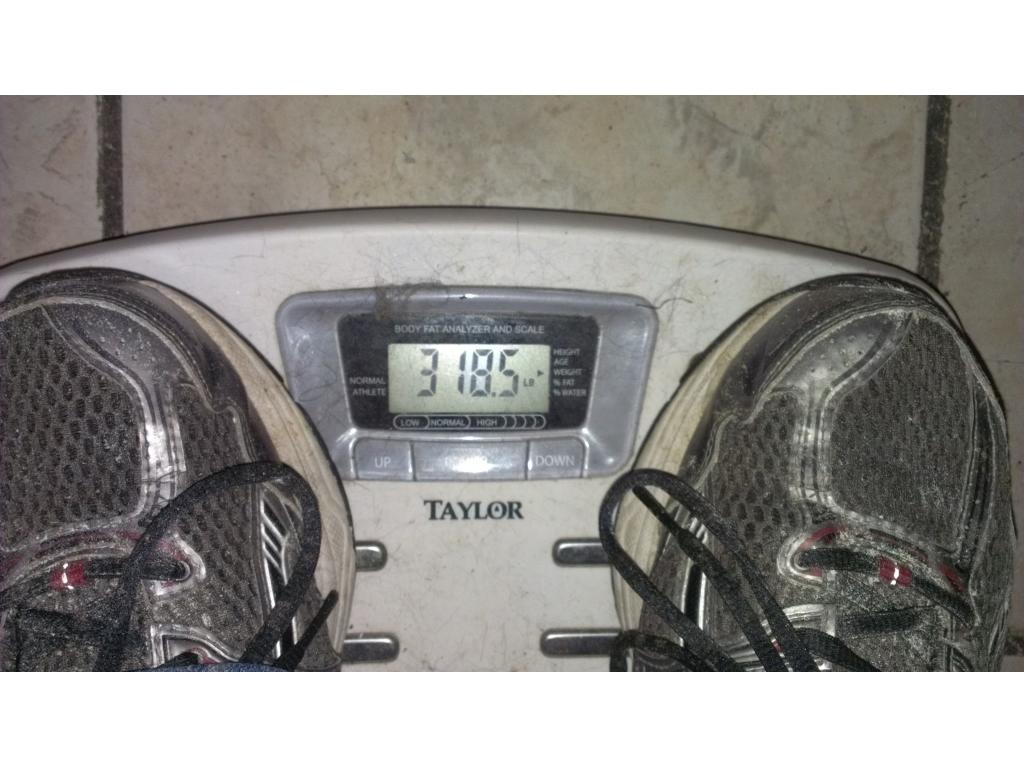
I weighted agian and my weight plus base , gearbox, riser , torso and vacuum backpack came out to 337321 is weight after I was holding the head and neck w servos, that's 3.5 pounds. Batteries are 16 pounds , previous weight of base and torso was 18.5. So this is a basic weight of 38 pounds without the arms , motherboard, hard drive , video card , ezb and sensors. With a fully loaded goal of 60 pounds I have 22 pounds room for the electronics (except batt) FUN STUFF