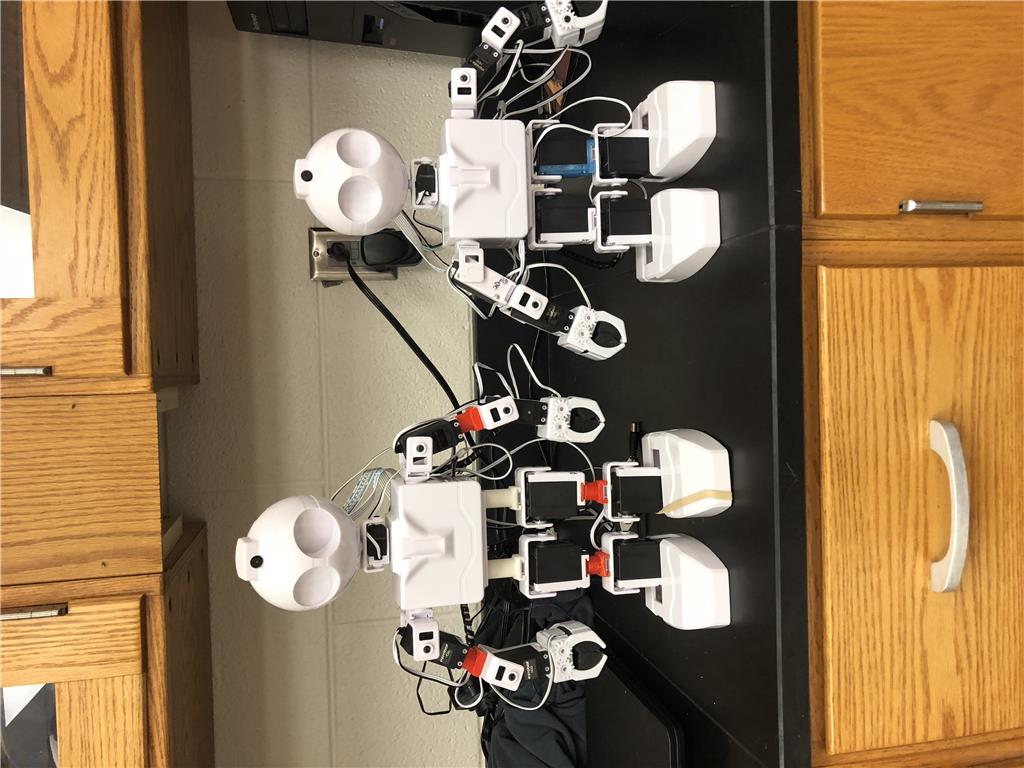
We have designed and 3D printed pieces with both a male and female parts, that connects in between the servos to make JD larger by 2.75 inches. This has also increased JD's speed tremendously because it takes longer steps.
By bmcnamee1
— Last update

Discover more robots
Urbanh's Target Bot
Control Target Bot in Synthiam ARC: EZ-Script moves D7 servo, reads D8 switch (GND+Signal, no resistors), triggers hit...
Cem's Inmoov With 7 Touch Screen Display And Lattepanda...
Run Synthiam ARC on a LattePanda V1.1 with a 7" touch screen for standalone InMoov control, auto-start projects and...
Fxrtst's Quantum Lift- Model CR-99
4WD sci-fi vehicle drive with EZ-Robot 360 servos, independent 4-wheel steering, mobile app control and IO Tiny; tight...

Cool idea @bmcnamee1 !
I look forward to seeing some footage
Ok, so no one is going to make the obvious jokes?
Ooooooh - I'm not going there, zap! Haha
That's a good idea extending jd. Smart idea!
any chance you post the stl files ?
love to see the extended robot in action.
This is something that I have been meaning to print. I might remake them so they're wider and fill in the gap more for aesthetic purposes.
@dj
is there a video of jd faster walk ?
I haven't made it yet, but I can see how it would be faster. He might have trouble getting up from the front if his arms aren't extended, though. But it'll be worth the test.
@dj
what about the adaptive walke like nao robot ?
ad rotation on the arms turnble grippers and longer , extra lever servo legs .
https://www.youtube.com/watch?v=OBGHU-e1kc0