Discover more robots
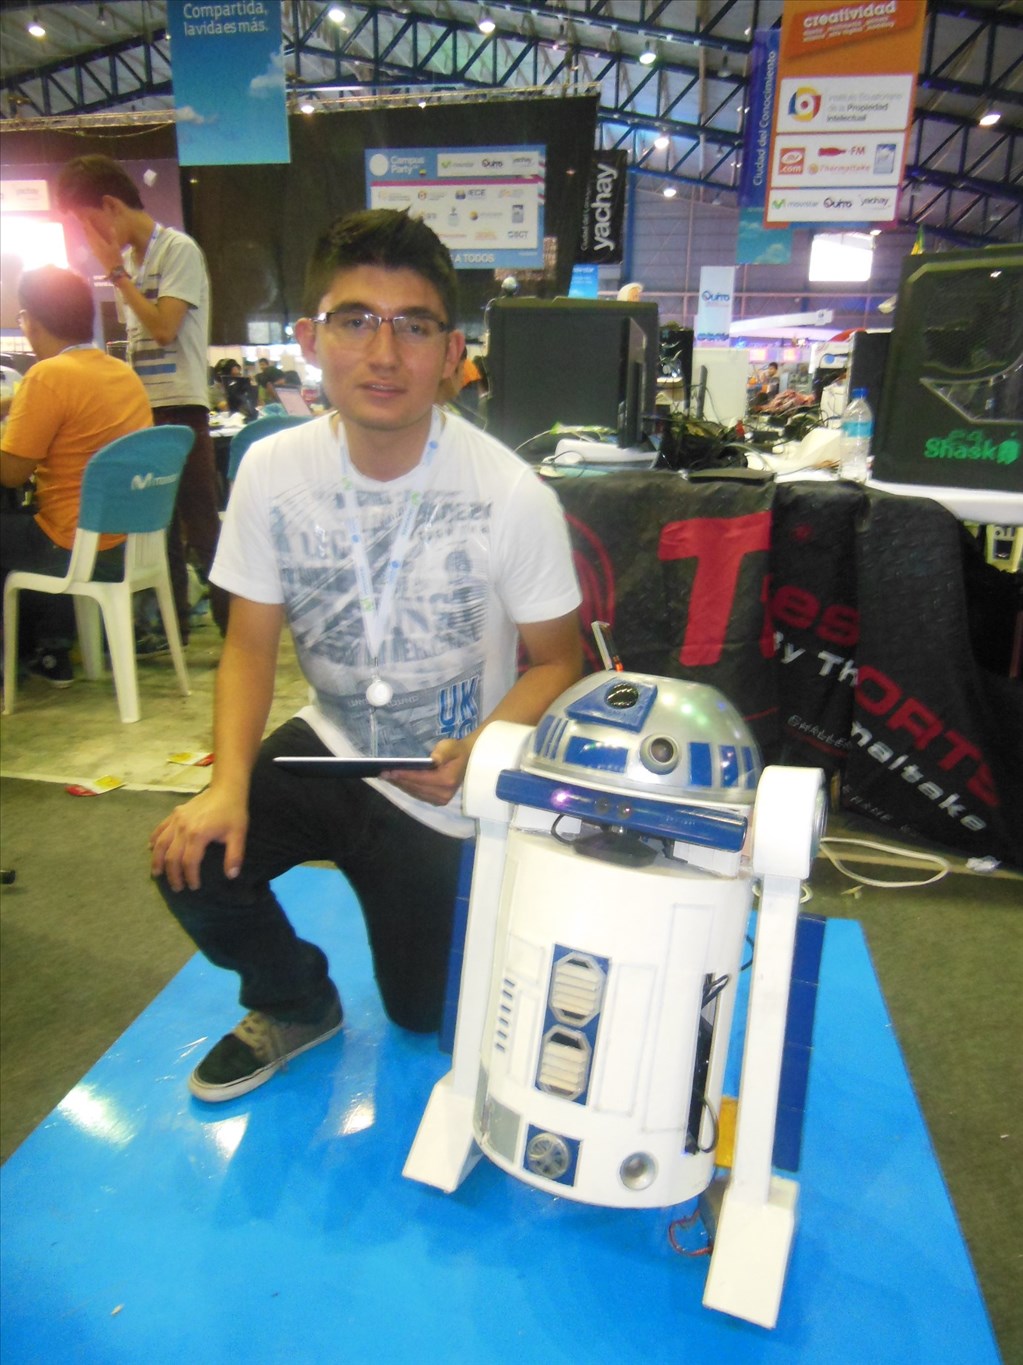
Edison2's R2d2 Star Wars - Kinect!
R2D2 integrated with Kinect using EZ-B showcased at Campus Party Quito-easy robot building with EZ-B, demos and...
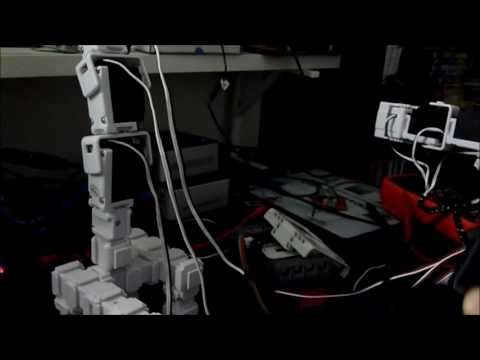
Fxrtst's ARC, Depth Sensor Plug In And Perception Neuron
IMU-based Perception Neuron motion capture glove maps human movement to servos, enabling low-cost robot control and...
Rb550f's Ez Robot Rover V2
EZ-Robot rover CP uses Sharper Image EVAC drivetrain with EZB V3, Chumby touchscreen, fan-cooled electronics, micro and...

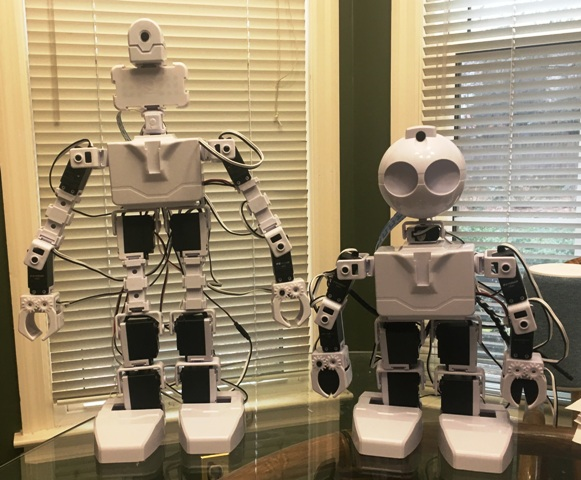
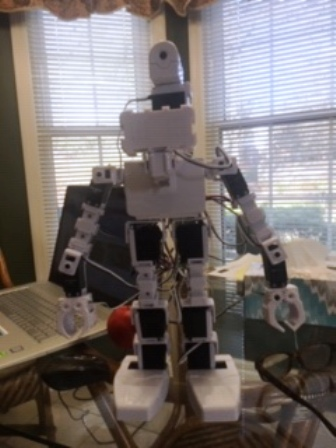
Looks good but for the walking , a trick we used way back on the really tall Robosapien RSV2 or Media bots,we added some rubber to the bottom of the feet to get more traction when it would slip on hard floors.
Great, I see I need more traction
Thanks
i would use the cube's to start trying to make a walking gait. it will be very hard to do with the large Extension Block.consider you dont us a gyro. with a big robot is also a good idea to make or use alu brackets insteadt of plastik ones, they tent to bend a little.look at many video about making walking gaits. see what all these robots do when starting to walk.NAO,WALKER,BIOLOID, they all do desame pose when starting to walk and that is bending the knees a little. also NAO name it the adaptive walk.jd bend his ankle on knee hight, all other robots have movement on the ankles forwart/backwarts/left/right.