I am not 6 foot tall, but I am taller the J D, I have longer legs and arms
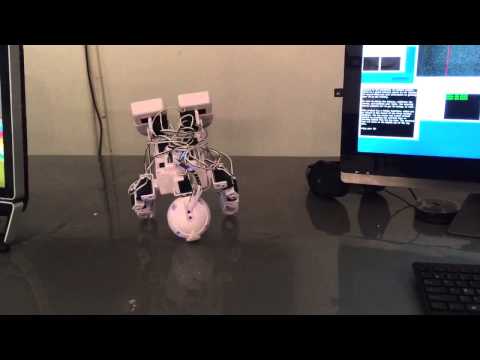
Here is a pic:
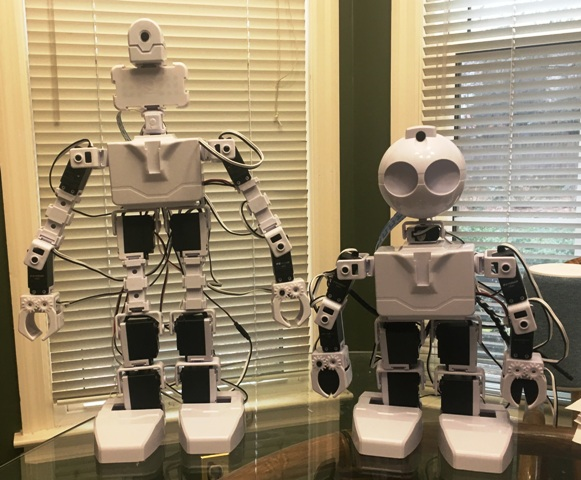
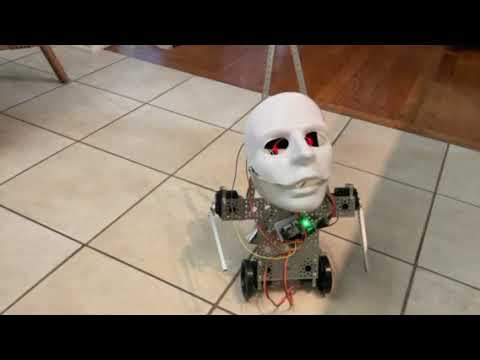
Added a servo for his head, re-arranged the RGB lights.
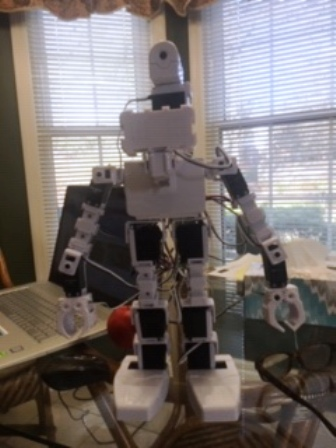
Has more movement now.
Here is a short video
 Auto Position (Gait)
— Create servo frames and actions to animate gaits and gestures with automatic motion planning, software ramping, movement panel, import/export
Try it →
Other projects from the same builder.
Robots the community built with Synthiam ARC. Get ideas for your next build.

Looks good but for the walking , a trick we used way back on the really tall Robosapien RSV2 or Media bots,we added some rubber to the bottom of the feet to get more traction when it would slip on hard floors.
Great, I see I need more traction
Thanks
i would use the cube's to start trying to make a walking gait. it will be very hard to do with the large Extension Block.consider you dont us a gyro. with a big robot is also a good idea to make or use alu brackets insteadt of plastik ones, they tent to bend a little.look at many video about making walking gaits. see what all these robots do when starting to walk.NAO,WALKER,BIOLOID, they all do desame pose when starting to walk and that is bending the knees a little. also NAO name it the adaptive walk.jd bend his ankle on knee hight, all other robots have movement on the ankles forwart/backwarts/left/right.