



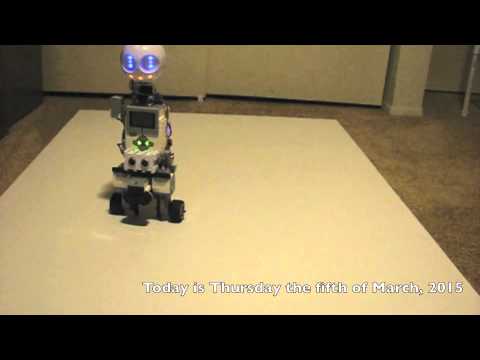
I got a 4 - in - 1 sensor and have put together a 2 wheeled balancing robot. Now I need to figure out some coding. I have the Initialization script and it works good - getting lots of data. I'm not having any luck after that. Does anyone have some scripting they would be willing to share with me to help me get going? Here's what I've got so far.
ControlCommand("MPU9150", Init)

sleep(100)

:loop
#Added these because $AccelX and $AccelY were not recognized later in the script for some reason.
$XAccel = $AccelX
$YAccel = $AccelY

if ("x" =0)

  print(1)

  sleep(2000)

  goto(loop)

endif

ControlCommand("MPU9150", RunOnce)

if($AccelX > 1000 and $AccelX < 1000)
servo(d4,108)
servo(d6,108)
endif

print("x: " + $XAccel)
print("y: " + $YAccel)

if($AccelX > 1000)

servo(d4,120)
servo(d6,61)

print(2)
elseif ($AccelX < 1000)
Servo(d4,61)
servo(D6,120)

print( 1)
endif
Sleep(100)
goto(loop)
I am working with a code that d. cochran posted awhile ago. It will change directions when it is tipped but will never stop. Also, after it has run for 30 seconds or so it will just keep running and the only way to stop the wheels is by disconnecting the power to the EZB.

Yeah - that's exactly what the purpose of it is
@DJ.... Ha, ha.... duh.... thanks
Oh and don't forget about OldBotBuilder and his Lego EV3 / EZB4. This will be the last of me participating here. You can find me on twitter if any questions.