


Does anyone have a wiring diagram to connect an EZB, Arduino UNO and two continuous servos to use the Wheel Encoder Skill?
 Ohmnilabs Standalone
— Connects Ohmnilabs Telepresence robot's UP Board COM to ARC, enabling drive and servo control (neck V0) and integration with ARC cameras.
Try it →

Does anyone have a wiring diagram to connect an EZB, Arduino UNO and two continuous servos to use the Wheel Encoder Skill?
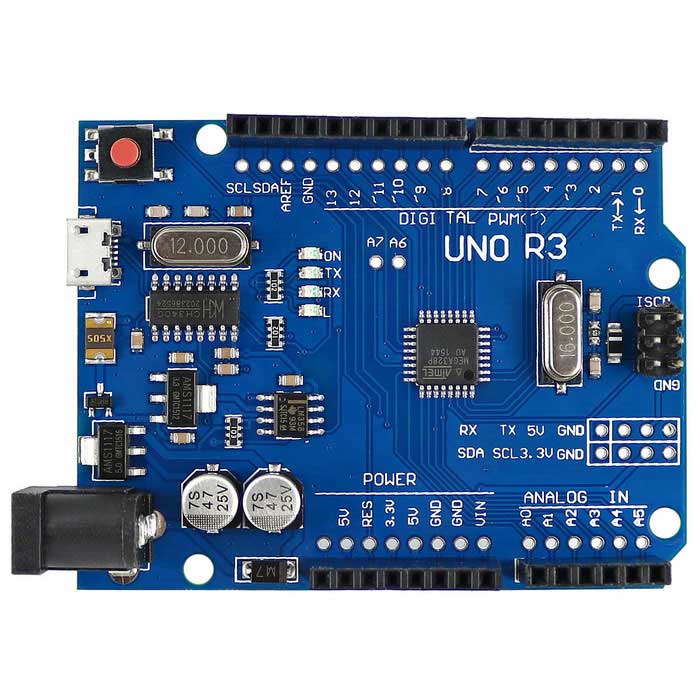

It's near the bottom of this page in the manual part (above comments): https://synthiam.com/Support/Skills/Navigation/Wheel-Encoder-Counter?id=17591
It is in a section titled "How to Use Wheel Encoder Counter"
Ok. That section refers to connecting a BN-880 compass. I have the EZB controlling 3 continuous rotation servos, each of which needs to have rotations counted by the Wheel Encoder Counter. I can't grasp how the servos can be controlled by the EZB and the UNO receive data on their rotation. Obviously something I am missing here.
Click on the link, DJ post #1
. Read that manual one that link comes up from top to bottom stopping at B - 880 campus.
read it several times it’s all there that Dj postage you the link.
also, watch the entire video that Dj has also posted on the same link
I don't see any info about a compass in DJ's link.