Thanks Rich, Richard R, and Luis for helping me with the scripting to get these sensors working.
More robots by bhouston
Other projects from the same builder.
Bhouston's Bob's Inmoov
InMoov robot running on EZ-Robot: project recaps, links to original builds and ongoing updates
Bhouston's Rubik's Cube Solving Robot
Run a Thingiverse 3D-printed Rubik's Cube robot with EZ-Robot servos and IoTiny; plugin for cube-solving, arm/gripper...
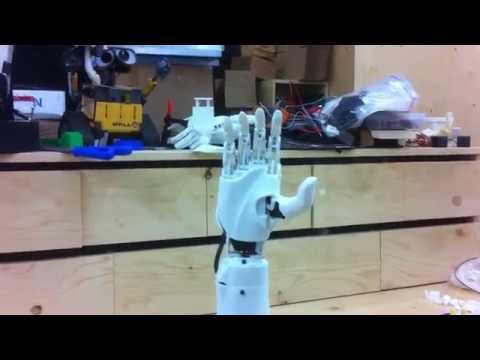
Bhouston's A New Hand For Inmoov?
InMoov hand hack: Exiii Handii modified for independent finger control, wrist with EZ-Robot lever servo, EZBv4 control...
Discover more robots
Robots the community built with Synthiam ARC. Get ideas for your next build.
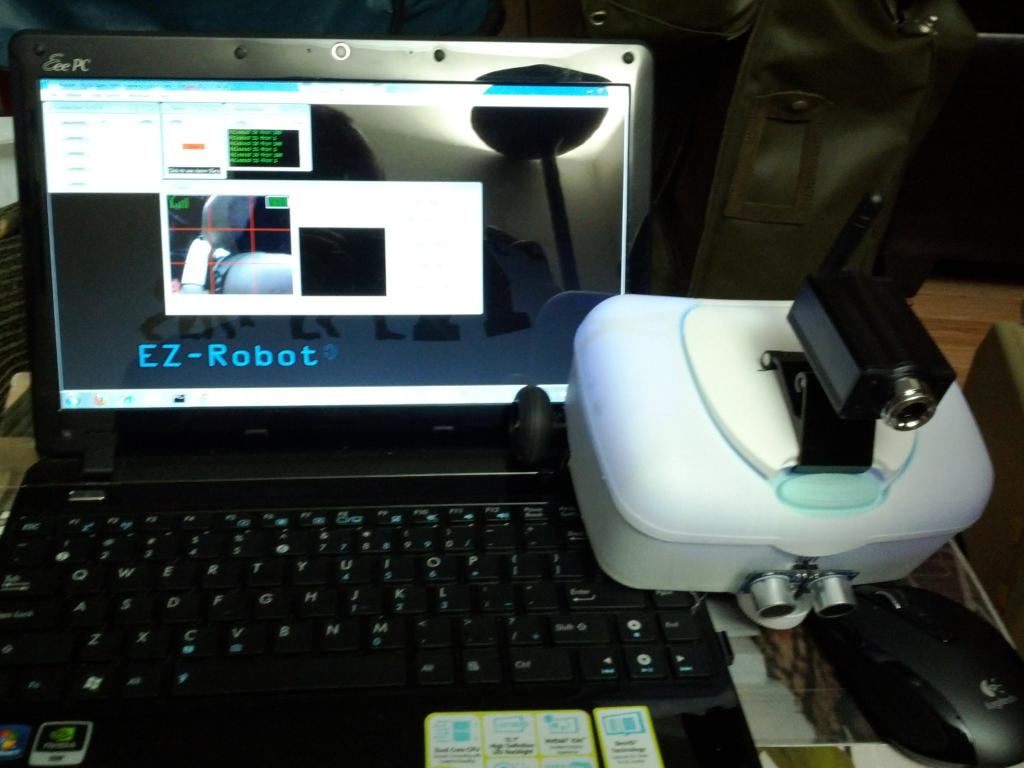
Tachyon's First Robot
Convert household junk into a remote-controlled robot using EZ-Robot EZ-B and Synthiam ARC for quick video control,...
Markthebotbldr's BB-R2 (Baby R2)
Build Baby R2 (BBR2) with supportfree 3D prints; create Synthiam ARC robot app and iPad mobile control for easy...
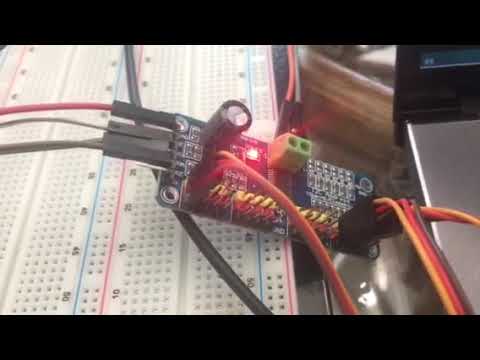
Ezang's ESP32 And ARC - Arduino And PCA 9685
ESP32 with PCA9685 in Synthiam ARC: control 3 servos now, 16 per board or chain for hundreds; shows servo results on ARC...

Bob, you're inmoov is great! I am so jealous. well a little jealous. I am still in the process of getting everything working on my inmoov. I'm not up to your speed yet but might be one day. I don't think as great as yours though.
thanks for sharing your videos are awesome.
:)
@Bob, Very nice! I want to get this ability into my full size B9. Can you post the script for this and the link to any threads on how you installed these sensors?
Here's the script for the Ultrasonic Sensors. I used two HC-SR04 Ultrasonic Sensors from EZ-Robot. They come with a voltage regulator which make them easy hook up. In the script you specify which ports the Ping and the Echo are attached to. I'm using 2 EZBv4's and have have them connected to Board #1. The servo movements in the script turn the head of the robot.
Let me know if you have any questions.
Sweet. Looks pretty simple.